Next Issue
Volume 8, June
Previous Issue
Volume 8, April


Vehicles, Volume 8, Issue 5 (May 2026) – 20 articles
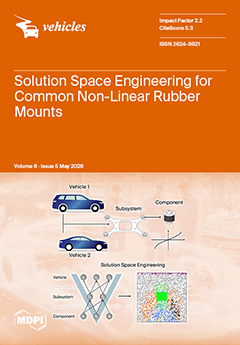
Cover Story (view full-size image): Modern vehicle development increasingly relies on common components to reduce cost, complexity, and development time across multiple vehicle platforms. However, designing common components becomes particularly challenging when strongly interacting systems and non-linear component behavior are involved, as conventional solution space engineering assumes constant functional properties. This study extends the methodology to enable the development of common non-linear components by introducing an additional design layer that defines commonality at the level of component design variables rather than operating-point-dependent properties. Using rear axle subframe mounts as an automotive case study, the approach demonstrates how system-specific requirements can be reconciled while preserving commonality potential in early vehicle development. View this paper
  • Issues are regarded as officially published after their release is announced to the table of contents alert mailing list.
  • You may sign up for e-mail alerts to receive table of contents of newly released issues.
  • PDF is the official format for papers published in both, html and pdf forms. To view the papers in pdf format, click on the "PDF Full-text" link, and use the free Adobe Reader to open them.
Order results
Result details
Section
Select all
Export citation of selected articles as:
23 pages, 6629 KB  
Article
Protective Materials and Cold-Side Airflow Effects on a Thermoelectric Generator for Automotive Exhaust Energy Recovery
by George Achitei, Lamara Achitei, Aristotel Popescu, Daria Sachelarie, Lidia Gaiginschi, Teodor Anita and Elena Adelina Chiriac
Vehicles 2026, 8(5), 114; https://doi.org/10.3390/vehicles8050114 - 21 May 2026
Viewed by 805
Abstract
Waste heat recovery from automotive exhaust gases represents an important strategy for improving vehicle energy efficiency. This study experimentally investigates the performance of a thermoelectric generator (TEG) system based on TEC1-12706 modules running under different cold-side cooling conditions and incorporating a Hot Rolled [...] Read more.
Waste heat recovery from automotive exhaust gases represents an important strategy for improving vehicle energy efficiency. This study experimentally investigates the performance of a thermoelectric generator (TEG) system based on TEC1-12706 modules running under different cold-side cooling conditions and incorporating a Hot Rolled Steel (HRS) protective layer on the hot side. The HRS plate was used to ensure uniform heat distribution and protect the thermoelectric module against thermal shocks generated by a 250 °C heat source. Four cooling regimes were experimentally analyzed: natural convection and forced airflows equivalent to 40, 60, and 90 km/h. The results proved that increasing airflow intensity significantly improved the temperature difference across the module, from approximately 16 ± 2 °C under natural convection to nearly 40 ± 2 °C at the highest airflow velocity. Correspondingly, the steady-state voltage generated increased from approximately 0.25 ± 0.01 V to over 0.60 ± 0.01 V under an 82 Ω resistive load. The measured hot-side temperature remained below 75 °C in all experimental conditions, confirming the thermal protection capability of the HRS layer. The experimental data also revealed a near-linear relationship between voltage and temperature difference, consistent with the Seebeck effect. The proposed configuration shows the feasibility of combining thermal protection and forced convection cooling to improve the stability and electrical performance of thermoelectric waste heat recovery systems intended for low-power automotive auxiliary applications. Full article
Show Figures

Figure 1

32 pages, 2330 KB  
Article
Multi-Domain Machine Learning Framework for Electric Vehicle Charging Prediction
by Hanan Thwany, Muhammad Alolaiwy and Mohamed Zohdy
Vehicles 2026, 8(5), 113; https://doi.org/10.3390/vehicles8050113 - 20 May 2026
Viewed by 828
Abstract
Electric vehicle (EV) adoption is rising rapidly, creating growing challenges for charging infrastructure planning, energy demand management, and grid stability. However, most existing studies rely on single-domain data, such as behavioral charging sessions or station metadata, which limits their ability to capture the [...] Read more.
Electric vehicle (EV) adoption is rising rapidly, creating growing challenges for charging infrastructure planning, energy demand management, and grid stability. However, most existing studies rely on single-domain data, such as behavioral charging sessions or station metadata, which limits their ability to capture the joint effects of user behavior, charger characteristics, and market context. To address this gap, this study proposes a multi-domain machine learning framework for EV charger-type prediction by integrating behavioral, infrastructure, and market-level data. Behavioral charging logs are transformed into structured event-token sequences and modeled using XLM-RoBERTa (Cross-lingual Language Model–RoBERTa), which is used here as a transformer-based sequence encoder to capture long-range dependencies in charging behavior. Structured infrastructure and market features are modeled using LightGBM and TabNet. The study contributes a unified multi-domain framework, a systematic comparison of transformer and tabular-learning models, and a broader evaluation through ablation analysis, cross-validation, confusion matrix analysis, and confidence calibration. The results show that multi-domain fusion consistently improves performance over single-domain learning. XLM-RoBERTa achieved the best overall performance on the fused dataset, with 98.76% accuracy and 97.86% weighted F1-score, while TabNet demonstrated stronger calibration and deployment reliability. Full article
Show Figures

Figure 1

21 pages, 2277 KB  
Article
Driver Behavioural Responses to Speed Cushions: A Driving Simulator Study
by Gaetano Bosurgi, Alessia Ruggeri, Giuseppe Sollazzo, Orazio Pellegrino and Domenico Passeri
Vehicles 2026, 8(5), 112; https://doi.org/10.3390/vehicles8050112 - 16 May 2026
Cited by 1 | Viewed by 878
Abstract
Traffic calming devices (TCMs) are widely implemented to reduce urban vehicle speeds; however, their influence on drivers’ direct control inputs remains underexplored. This study examines how drivers redistribute braking, throttle and steering inputs in the presence of speed cushions, extending driver–infrastructure interaction assessment [...] Read more.
Traffic calming devices (TCMs) are widely implemented to reduce urban vehicle speeds; however, their influence on drivers’ direct control inputs remains underexplored. This study examines how drivers redistribute braking, throttle and steering inputs in the presence of speed cushions, extending driver–infrastructure interaction assessment beyond speed-only metrics. A driving simulator reproduced an urban corridor in Messina (Italy). Twenty-five drivers completed three scenarios: baseline without traffic calming (No TCM), daytime with speed cushions and nighttime with speed cushions. Cushion colour (red/blue) and width (1.5, 1.8, 2.1 m) were varied. Vehicle telemetry was analyzed using repeated-measures ANOVA with corrected post hoc tests and partial η2 as effect size. The analysis was complemented by paired within-subject comparisons, bootstrap confidence intervals and additional transient indicators computed on travelled-distance windows to support transparent effect interpretation without replacing the RM-ANOVA framework. Compared with No TCM, speed cushions increased mean braking (+224% Day, +372% Night) and reduced the mean normalized throttle input by approximately 55%, with stronger braking at night. Width primarily influenced throttle release and steering corrections, whereas colour modulated braking under reduced visibility. Despite limitations related to sample size and simulation, the findings provide actionable evidence for contexts where cushion width and colour are not standardized. Full article
Show Figures

Figure 1

16 pages, 997 KB  
Article
Multi-Parameter Optimization of Vehicle Performance for a Four-Wheel-Drive Formula Student Electric Race Car
by Chun Ren, Zhongxuan Xiong, Kangjie Liu, Jiayu Shen, Dapai Shi and Xuefeng Yang
Vehicles 2026, 8(5), 111; https://doi.org/10.3390/vehicles8050111 - 15 May 2026
Viewed by 571
Abstract
With the rapid development of Formula Student competitions, higher demands are being placed on the vehicle performance of race cars. To further enhance vehicle performance, this study investigates the optimization of three key indicators: maximum speed, 0–100 km/h acceleration time, and energy consumption [...] Read more.
With the rapid development of Formula Student competitions, higher demands are being placed on the vehicle performance of race cars. To further enhance vehicle performance, this study investigates the optimization of three key indicators: maximum speed, 0–100 km/h acceleration time, and energy consumption under the NEDC driving cycle. First, a vehicle physical model was established on the AVL CRUISE 2019 R2 platform based on the vehicle parameters, and corresponding simulation tasks were configured. Meanwhile, a numerical model was developed in MATLAB R2022a and validated by comparing the predicted maximum speed, acceleration time, and energy consumption with the CRUISE simulation results. On this basis, a genetic algorithm was employed to optimize the battery pack parallel number and the total reduction ratio so as to improve the vehicle performance. The optimized parameters were then re-imported into the CRUISE model for further simulation verification. The results indicate that, compared with the original configuration, the optimized scheme leads to a slight increase in acceleration time, while significantly improving the maximum speed and reducing the energy consumption under the NEDC cycle. Overall, the proposed optimization method effectively enhances the vehicle performance of the Formula Student electric race car. Full article
Show Figures

Figure 1

32 pages, 8065 KB  
Article
Rapid Physics-Based Synthesis of Diesel Engine Models for Hybrid Powertrain Optimization
by Rupert Tull de Salis
Vehicles 2026, 8(5), 110; https://doi.org/10.3390/vehicles8050110 - 13 May 2026
Viewed by 541
Abstract
Concept-phase planning of diesel-engined hybrid vehicles requires rapid engine synthesis, including brake-specific fuel consumption (BSFC) estimation, with minimal input data. Fuel savings from hybridization arise partly through engine downsizing and engine-off operation, so trade studies depend on knowing the dependence of BSFC on [...] Read more.
Concept-phase planning of diesel-engined hybrid vehicles requires rapid engine synthesis, including brake-specific fuel consumption (BSFC) estimation, with minimal input data. Fuel savings from hybridization arise partly through engine downsizing and engine-off operation, so trade studies depend on knowing the dependence of BSFC on engine sizing and speed and load conditions. This paper presents a method for synthesizing hypothetical modern diesel engines of any given size for the purpose of trade studies. The synthesized engines match the performance and efficiency capabilities of commercially available units. Relationships are developed between rated power, rated speed, peak torque, displacement and cylinder count for four vehicle application classes. Together with a BSFC estimation method, these relationships form a complete engine synthesis chain from rated power to a full torque curve and BSFC map. Known values may be substituted, such as minimum BSFC, wherever published data are available. The method supports continuous scaling. Full article
(This article belongs to the Section Powertrain and Energy Systems)
Show Figures

Figure 1

24 pages, 3119 KB  
Article
PHR-Net: Proposal-Level Historical Retrieval for Non-Stationary Temporal Consistency in Trajectory Prediction
by Bo Zhang and Ming Xu
Vehicles 2026, 8(5), 109; https://doi.org/10.3390/vehicles8050109 - 12 May 2026
Viewed by 468
Abstract
Multi-agent trajectory prediction serves as a critical component in autonomous driving systems, bridging environment perception, behavior understanding, and motion planning. Its outputs not only affect candidate trajectory evaluation and interactive decision-making but also directly influence downstream processes such as risk anticipation, braking and [...] Read more.
Multi-agent trajectory prediction serves as a critical component in autonomous driving systems, bridging environment perception, behavior understanding, and motion planning. Its outputs not only affect candidate trajectory evaluation and interactive decision-making but also directly influence downstream processes such as risk anticipation, braking and yielding, and safety margin allocation. Therefore, obtaining accurate and stable prediction results is of great importance. Although existing methods have achieved remarkable progress in single-timestep prediction accuracy, most of them still adopt an independent decoding paradigm under a sliding-window setting. As a result, during continuous online prediction, these models are prone to frequent mode switching, temporal discontinuities in overlapping segments, and local trajectory jitter, which become particularly pronounced in complex interactive scenarios such as yielding, merging, and unprotected turning. To address these issues, this paper proposes PHR-Net, a two-stage proposal-level historical retrieval framework that introduces cross-timestep historical context to perform consistency-aware refinement of current predictions on top of multimodal coarse proposals. Experiments on the Argoverse 1 benchmark show that PHR-Net achieves competitive performance under both Top-1 and Top-6 settings. PHR-Net obtains a Top-1 minFDE of 1.0834 and MR of 0.1046 and achieves an MR of 0.1027 under the Top-6 setting. In the overlapping-interval consistency evaluation, PHR-Net reduces the summed ADE to 2.08. These results show that proposal-level historical retrieval improves endpoint reliability and cross-timestep temporal consistency. Full article
Show Figures

Figure 1

18 pages, 5081 KB  
Article
A Comparative Study on Situation Awareness While Reading in a Highly Automated Vehicle
by Alexander G. Mirnig, Sandra Trösterer and Mark Colley
Vehicles 2026, 8(5), 108; https://doi.org/10.3390/vehicles8050108 - 12 May 2026
Cited by 1 | Viewed by 650
Abstract
When driving a partially automated vehicle, maintaining situation awareness is essential for users to be better prepared to take over. A primary challenge is maintaining awareness while the user is occupied with another task without tunneling attention towards individual elements. To investigate this, [...] Read more.
When driving a partially automated vehicle, maintaining situation awareness is essential for users to be better prepared to take over. A primary challenge is maintaining awareness while the user is occupied with another task without tunneling attention towards individual elements. To investigate this, we conducted an experimental study in our driving simulator (n = 20) comparing an indirect LED (light-emitting diode) visualization of relevant objects in the driver’s field of view with a combined condition of an indirect LED + direct HUD (head-up display) visualization. The participants’ situation awareness scores were higher under the combined condition. However, the scores dropped significantly for objects outside the LED + HUD visualization. We conclude that the indirect object indication is not effective in countering tunneling effects from the HUD, and neither does it provide a satisfactory trade-off when deployed on its own, i.e., without direct indication in addition. Full article
Show Figures

Figure 1

37 pages, 2340 KB  
Article
Combinatorial Optimization of Shunting Operations for Industrial Sidings Adjacent to Railway Stations
by Alisher Baqoyev, Azizjon Yusupov, Sakijan Khudayberganov, Bauyrzhan Sarsembekov, Utkir Khusenov, Aleksandr Svetashev, Shokhrukh Kayumov, Muslima Akhmedova and Mafratkhon Tokhtakhodjayeva
Vehicles 2026, 8(5), 107; https://doi.org/10.3390/vehicles8050107 - 10 May 2026
Viewed by 751
Abstract
The main objective of this study was to reduce the dwell time of wagons at stations and to improve the efficiency of shunting locomotive utilization. This is a combinatorial problem, since an increase in the number of loading and unloading fronts leads to [...] Read more.
The main objective of this study was to reduce the dwell time of wagons at stations and to improve the efficiency of shunting locomotive utilization. This is a combinatorial problem, since an increase in the number of loading and unloading fronts leads to a sharp growth in the number of feasible service variants. During the research, a mathematical model describing the servicing process of industrial sidings was developed. This study addressed the problem of determining the optimal sequence of wagon deliveries and the optimal distribution of workload among shunting locomotives. For conditions under which two or more shunting locomotives are used, an optimization method based on the indicator of wagon-hour reduction (σ) was proposed for allocating loading and unloading fronts. Using combinatorial properties, it was shown that many possible allocation variants are symmetric, which allowed for the development of a mathematical solution that simplifies the search for an optimal solution. Computational results demonstrated that, at the hypothetical railway station “N-1”, applying the optimal service sequence reduces wagon dwell time by 21% compared with an arbitrary sequence. At the hypothetical station “N-2”, distributing wagon groups between two shunting locomotives improves the efficiency of the servicing process by 26% compared with using a single locomotive. The results based on real data from the “B-2” railway station show that the proposed method provides an improvement of approximately 31.3% compared to the current operational practice, while Smith’s rule achieves an improvement of 14.9%. Based on the proposed model and algorithm, a software tool was developed to automatically determine servicing sequences for loading and unloading fronts, analyze alternatives, and evaluate shunting locomotive efficiency. Full article
(This article belongs to the Special Issue Models and Algorithms for Railway Line Planning Problems)
Show Figures

Figure 1

27 pages, 4328 KB  
Article
How Do Human-Driven Vehicles Overtake Pedestrians? Overtaking Strategy Modelling Study Based on Driving Simulator Experiments
by Biming Zhao, Yiman Dong, Shulei Sun, Kunfan Liu, Xiaorong Huang, Bojiang Chen and Wenyan Zhang
Vehicles 2026, 8(5), 106; https://doi.org/10.3390/vehicles8050106 - 8 May 2026
Viewed by 380
Abstract
In mixed pedestrian–vehicle traffic environments, overtaking pedestrians by vehicles is a prevalent and complex human–vehicle interaction scenario. However, this maneuver often leads to accidents, resulting in injuries and fatalities, primarily due to inadequate in frastructure, limited pedestrian safety awareness, and suboptimal driver behavior. [...] Read more.
In mixed pedestrian–vehicle traffic environments, overtaking pedestrians by vehicles is a prevalent and complex human–vehicle interaction scenario. However, this maneuver often leads to accidents, resulting in injuries and fatalities, primarily due to inadequate in frastructure, limited pedestrian safety awareness, and suboptimal driver behavior. To mitigate such accidents and develop active vehicle safety systems and autonomous driving algorithms based on human–vehicle interaction data, it is crucial to investigate the overtaking behavior of human drivers. This study examines driver overtaking behavior under various conditions through driving simulator experiments and evaluates how different experimental variables influence driver performance. Using data from 12 skilled drivers, a risk corridor for vehicles overtaking pedestrians is established and a lateral distance prediction model is developed. Based on this established risk corridor, a vehicle overtaking strategy is proposed. Furthermore, to assess the risk level associated with overtaking pedestrians, pedestrians’ subjective risk perceptions are quantified. The simulation results indicate that the maximum lateral error of the vehicle is approximately 0.14 m, the maximum heading error is about 0.06 radians, and the vehicle’s trajectory during pedestrian overtaking remains within the defined risk corridor. These findings are consistent with the operational characteristics of human drivers. Full article
(This article belongs to the Section Intelligent and Connected Mobility)
Show Figures

Figure 1

22 pages, 19410 KB  
Article
Model Predictive Control Optimization Energy Management Strategy with Fused Temporal Features Speed Prediction
by Yong Chen, Yuhai Li, Yuguo Xu, Baitan Ma and Qing Zhou
Vehicles 2026, 8(5), 105; https://doi.org/10.3390/vehicles8050105 - 8 May 2026
Viewed by 691
Abstract
To address the stochasticity of real-world driving conditions and the optimality of energy allocation in a hybrid electric vehicle (HEV), this paper proposes a model predictive control (MPC) energy management strategy based on the Stacked–CNN–BiLSTM–Attention (SCBA) network. First, an SCBA-based vehicle speed prediction [...] Read more.
To address the stochasticity of real-world driving conditions and the optimality of energy allocation in a hybrid electric vehicle (HEV), this paper proposes a model predictive control (MPC) energy management strategy based on the Stacked–CNN–BiLSTM–Attention (SCBA) network. First, an SCBA-based vehicle speed prediction model is constructed by enhancing the bidirectional long short-term memory (BiLSTM) network with a double-layer convolutional structure and an attention mechanism, enabling the model to extract and fuse temporal features of the speed sequence, thereby overcoming the insufficient characterization of local abrupt speed variations and improving the accuracy of speed prediction. Secondly, a novel global optimization algorithm, the Rüppell’s Fox Optimizer (RFO), which possesses strong global search capability, is embedded as the solver for the multi-objective optimization problem in a rolling-horizon MPC framework, delivering superior energy-saving performance. Simulation results show that, compared with the conventional BiLSTM model, the proposed speed prediction model reduces the maximum root-mean-square error (RMSE) by 46.12% and the end-point prediction RMSE by 62.6%. The proposed RFO-MPC energy management strategy reaches 97.04% of the fuel-saving performance of dynamic programming (DP), representing a 5.6% improvement over the DP-MPC strategy. Finally, the effectiveness of the energy management strategy (EMS) is verified by hardware-in-the-loop (HIL) testing. Full article
(This article belongs to the Special Issue Advanced Vehicle Powertrain Control and Energy Management Strategies)
Show Figures

Figure 1

18 pages, 1815 KB  
Article
An Integer Linear Programming Model for the Crew Re-Scheduling Problem Under Crew Unavailability in Urban Rail Transit
by Songpo Yang, Yumiao Wu and Mengjiao Zhao
Vehicles 2026, 8(5), 104; https://doi.org/10.3390/vehicles8050104 - 7 May 2026
Cited by 1 | Viewed by 521
Abstract
The crew re-scheduling problem (CRSP) is a critical challenge in the operation and management of urban rail transit (URT) systems, especially when restoring service after disruptions. When a crew member unexpectedly leaves duty due to emergency events like illness, the train assigned to [...] Read more.
The crew re-scheduling problem (CRSP) is a critical challenge in the operation and management of urban rail transit (URT) systems, especially when restoring service after disruptions. When a crew member unexpectedly leaves duty due to emergency events like illness, the train assigned to that crew may get stranded in one operating direction, which will block the following trains operating in the same direction. To address this issue, this study first introduces a closed-loop driving strategy. This strategy reallocates limited crew resources across both operating directions to maintain the basic operations of the URT system during emergency periods. On this basis, an integer linear programming (ILP) model is developed to describe the dynamic adjustments of train departure times. Valid inequalities are incorporated to generate feasible crew task sets rapidly, and the proposed model is solved by using Gurobi. To meet the stringent time requirements for rescheduling during disruptions, an improved greedy algorithm is further designed to manage crew assignment under emergency conditions efficiently. Finally, the effectiveness of the proposed approach is evaluated through a real-world case study based on the Beijing urban rail transit network. The results demonstrate that the proposed model can respond rapidly within 30 min after an incident occurs. It not only limits the generation time of each crew task to within 1 min but also achieves a relative working balance between crews by combining short-duration tasks. Full article
(This article belongs to the Special Issue Optimization and Management of Urban Rail Transit Network)
Show Figures

Figure 1

30 pages, 5002 KB  
Article
Designing Rubber Mounts with Non-Linear Functional Properties for Commonality Using Solution Space Engineering
by Sebastian Wagner and Dieter Schramm
Vehicles 2026, 8(5), 103; https://doi.org/10.3390/vehicles8050103 - 7 May 2026
Viewed by 493
Abstract
Designing strongly interacting vehicle components in the early development phase is challenging because numerous requirements, uncertainties, and conflicting objectives significantly limit feasible design solutions. Achieving optimal commonality is particularly complex when a single component must satisfy the requirements of multiple systems. Solution space [...] Read more.
Designing strongly interacting vehicle components in the early development phase is challenging because numerous requirements, uncertainties, and conflicting objectives significantly limit feasible design solutions. Achieving optimal commonality is particularly complex when a single component must satisfy the requirements of multiple systems. Solution space engineering is an effective method for identifying robust common solutions and has been successfully applied to components with linear properties. However, its applicability is limited for components with non-linear properties, as their properties vary with the operating point. Consequently, evaluating component commonality across systems cannot rely solely on functional properties, since these are operating-point-dependent and system-specific. Both boundary conditions and quantities of interest differ between systems and must be considered to avoid unnecessary restriction of the solution space during development. This paper presents an extension of solution space engineering for developing common components with non-linear properties, explicitly accounting for differing system requirements at identical operating points. An enhanced layering technique is introduced that establishes commonality at the level of component design variables. The proposed approach is demonstrated through the design of rear axle subframe mounts. Full article
(This article belongs to the Special Issue Vehicle Design Processes, 3rd Edition)
Show Figures

Figure 1

2 pages, 121 KB  
Editorial
Vehicles: Four New Journal Sections Established
by Mohammed Chadli
Vehicles 2026, 8(5), 102; https://doi.org/10.3390/vehicles8050102 - 6 May 2026
Viewed by 349
Abstract
The landscape of automotive and transportation engineering is evolving at an unprecedented pace, driven by a growing demand for safer and smarter mobility [...] Full article
19 pages, 10671 KB  
Article
A Vehicle Type Recognition Network Based on Feature Comparison and Mixture of Experts Model
by Taotao Hu, Xiufeng Zhao and Luxia Yang
Vehicles 2026, 8(5), 101; https://doi.org/10.3390/vehicles8050101 - 3 May 2026
Viewed by 537
Abstract
To address the challenges of insufficient feature fusion and incomplete multi-scale information capture in complex traffic scenarios, we propose a vehicle type recognition network based on feature comparison and the Mixture of Experts (MoE) model. Specifically, the MobileNetV4 backbone is introduced to enhance [...] Read more.
To address the challenges of insufficient feature fusion and incomplete multi-scale information capture in complex traffic scenarios, we propose a vehicle type recognition network based on feature comparison and the Mixture of Experts (MoE) model. Specifically, the MobileNetV4 backbone is introduced to enhance deep feature extraction for vehicle targets. Meanwhile, we design a Multi-scale Interleaving Fusion Module (MSIFM), which progressively transmits feature channels via an interleaving structure to capture multi-scale features while enhancing vehicle feature representation. Moreover, we devise a Feature Compare Enhancement Module (FCEM) to efficiently fuse feature maps with different semantic information. By performing feature comparison, it strengthens strongly correlated features while suppressing weakly correlated ones. Finally, we design a Mixture of Experts Feature Enhancement Module (MOEFEM) to aggregate multi-scale feature maps and adaptively capture detailed vehicle features through multiple expert units. Experimental results demonstrate that our method achieves mAP improvements of 2.2% and 2.4% over YOLOv11 on UA-DETRAC and BDD100K, respectively. The proposed method not only improves detection accuracy significantly but also maintains real-time efficiency, providing a practical solution for high-precision vehicle type recognition. It offers valuable technical support for intelligent transportation systems, smart city management, and autonomous driving safety. Full article
(This article belongs to the Section Vehicle Dynamics and Control)
Show Figures

Figure 1

30 pages, 2472 KB  
Article
Energy Consumption Prediction for an Electric Vehicle Using Machine Learning: A Comparative Study of Regression, Ensemble, and LSTM-Based Models
by Juan Diego Valladolid and Juan P. Ortiz
Vehicles 2026, 8(5), 99; https://doi.org/10.3390/vehicles8050099 - 1 May 2026
Cited by 2 | Viewed by 4154
Abstract
Accurate energy consumption prediction is fundamental for enhancing range estimation and trip planning in battery electric vehicles (BEVs) under real-world conditions. This study develops a route-level benchmark utilizing 1 Hz data acquired via ECU/OBD-II interfaces (CAN 500 kbps) across ten diverse real-world driving [...] Read more.
Accurate energy consumption prediction is fundamental for enhancing range estimation and trip planning in battery electric vehicles (BEVs) under real-world conditions. This study develops a route-level benchmark utilizing 1 Hz data acquired via ECU/OBD-II interfaces (CAN 500 kbps) across ten diverse real-world driving routes. The input feature set comprises vehicle speed, longitudinal acceleration, estimated motor torque, road altitude, and accelerator pedal position. Ground truth energy consumption was derived from battery voltage and current, integrated via the trapezoidal rule. We performed a comparative analysis between five memoryless regressors (FNN, SVR, GPR, QRNN, and Bagged Trees) and three sequence models (LSTM, GRU, and BiLSTM) trained on 20-second temporal windows. The results indicate that the GRU model achieved the highest overall performance (mean RMSE = 0.1142 kWh, R2 = 0.9545 and MAE = 0.072 kWh), while Bagged Trees emerged as the most robust static model (mean RMSE = 0.1587 kWh). Temporal models outperformed static ones on routes with high dynamic variability, whereas Bagged Trees excelled in five specific scenarios. These findings provide a controlled within-route benchmark for time-resolved cumulative energy estimation and highlight the need for chronological and cross-route validation before drawing deployment-oriented generalization claims. Full article
(This article belongs to the Special Issue Application of Machine Learning in Electric Vehicles)
Show Figures

Graphical abstract

21 pages, 12844 KB  
Article
Unsupervised Domain Adaptation with Multimodal Fusion for Monocular 3D Object Detection
by Jin Jiang, Jidong Dai, Wei Li, Yuquan Zhou, Maozhang Ye, Jianhuan Zhang and Chentao Zhang
Vehicles 2026, 8(5), 98; https://doi.org/10.3390/vehicles8050098 - 1 May 2026
Viewed by 792
Abstract
This paper presents UM3D, an end-to-end unsupervised domain adaptation framework for monocular 3D object detection. Monocular 3D object detection is appealing due to its low cost, yet it suffers from limited depth cues and poor cross-domain generalization when labeled data are scarce. Existing [...] Read more.
This paper presents UM3D, an end-to-end unsupervised domain adaptation framework for monocular 3D object detection. Monocular 3D object detection is appealing due to its low cost, yet it suffers from limited depth cues and poor cross-domain generalization when labeled data are scarce. Existing Pseudo-LiDAR methods require supervised training and propagate depth estimation errors to downstream detection, while current unsupervised domain adaptation (UDA) approaches exploit only a single modality and lack effective pseudo-label quality control. UM3D addresses these limitations through two key designs: (1) a quality-aware pseudo-label generation strategy with object-level random scaling and a memory bank refinement mechanism; and (2) an end-to-end differentiable pipeline that integrates multimodal fusion of image and Pseudo-LiDAR features with a multi-network consistency loss, which jointly optimizes depth estimation and 3D detection via backpropagation. Notably, the entire pipeline requires only a single monocular camera at inference; the Pseudo-LiDAR representation is generated internally from the same image, and thus the multimodal fusion integrates image and Pseudo-LiDAR features without requiring additional sensors. Extensive experiments across KITTI, nuScenes, Waymo, and Lyft demonstrate that UM3D generally outperforms existing UDA methods. In particular, a 19.30% relative APBEV improvement is achieved under easy conditions through end-to-end joint training compared to independent depth estimation, and up to 76.81% of the domain gap is closed on the WOD → KITTI benchmark. Full article
(This article belongs to the Section Intelligent and Connected Mobility)
Show Figures

Figure 1

32 pages, 5359 KB  
Article
Fog & V2V: A CARLA-Based Comparative Study of No Perception, Degraded Sensors, and Cooperative Alerts with MPC-Based Collision Avoidance
by Hamza El Yanboiy, Mohammed Chaman, Mohammed Bouabdellaoui, Adam Khechchab and Youssef El Merabet
Vehicles 2026, 8(5), 97; https://doi.org/10.3390/vehicles8050097 - 1 May 2026
Cited by 1 | Viewed by 1089
Abstract
This study investigates the safety limitations of autonomous vehicles operating under dense fog conditions, where sensor performance is severely degraded, and explores the potential of cooperative control for collision avoidance. A comparative framework is developed using the CARLA simulator to analyze four driving [...] Read more.
This study investigates the safety limitations of autonomous vehicles operating under dense fog conditions, where sensor performance is severely degraded, and explores the potential of cooperative control for collision avoidance. A comparative framework is developed using the CARLA simulator to analyze four driving configurations: no perception and no communication, degraded LiDAR–radar sensing, V2V-assisted Model Predictive Control (MPC), and V2V-assisted MPC enhanced with predictive buffering. The methodology integrates fog-dependent perception modeling, cooperative hazard messaging, and real-time MPC-based longitudinal control, and evaluates system performance through multiple simulation trials under urban and highway conditions. Key performance indicators include time-to-collision, reaction time, maximum deceleration, jerk, and collision occurrence. The results demonstrate that perception-only strategies lead to late reactions and unsafe emergency braking, with minimum TTC values as low as 0.29 s and frequent collision events. In contrast, V2V-assisted MPC significantly improves anticipation and driving comfort, while the proposed predictive buffering approach achieves a 0% collision rate and increases the minimum TTC to approximately 1.93 s. The inclusion of predictive buffering further enhances robustness against communication losses, enabling smoother deceleration and consistently safe inter-vehicle spacing. Overall, the findings confirm that cooperative V2V communication combined with predictive control effectively compensates for fog-induced perception degradation and represents a viable solution for improving safety and reliability in low-visibility autonomous driving scenarios. Full article
Show Figures

Figure 1

37 pages, 11499 KB  
Article
Automated Mid-Surface Mesh Generation Method for Automotive Plastic Parts Based on Deep Learning
by Hongbin Tang, Zehui Huang, Jingchun Wang, Jianjiao Deng, Shibin Wang, Zhiguo Zhang and Zhenjiang Wu
Vehicles 2026, 8(5), 96; https://doi.org/10.3390/vehicles8050096 - 1 May 2026
Viewed by 1424
Abstract
Automotive plastic parts present multiple challenges for Computer-Aided Engineering (CAE) simulation modeling, including complex thin-walled geometries, difficulties in meshing fine features (e.g., clips and snap-fits), and time-consuming manual processing with inconsistent quality. To address these issues, this paper proposes an automated method for [...] Read more.
Automotive plastic parts present multiple challenges for Computer-Aided Engineering (CAE) simulation modeling, including complex thin-walled geometries, difficulties in meshing fine features (e.g., clips and snap-fits), and time-consuming manual processing with inconsistent quality. To address these issues, this paper proposes an automated method for generating mid-surface meshes. The proposed approach integrates AI-based feature recognition, point cloud registration, and geometric fitting. First, a specialized point cloud dataset consisting of 132,000 samples of plastic part features was constructed. Using a PointNet++ model, precise semantic segmentation of typical features, such as clips and backing plates, was achieved. Subsequently, a library of typical features was established, and an FPFH-ICP point cloud registration strategy was implemented. Based on the matching rate, an adaptive selection between two processing paths, direct standard mesh replacement and segmentation-fitting generation was performed. For features with low matching rates, a suite of segmentation-fitting algorithms was proposed. These algorithms incorporate incomplete cylinder parameter extraction, Monte Carlo boundary identification, and internal point cloud reordering, thereby facilitating high-quality mid-surface mesh generation for complex topological structures. Finally, experimental validation was conducted on typical automotive interior plastic parts as well as on new cross-platform vehicle models. The results demonstrate that the proposed method reduces mesh modeling time by 67% while preserving the accuracy of geometric feature restoration. The mesh quality compliance rate increases from 52.27% to 90.9% with the proposed method, reaching a level comparable to that of professional manual meshing. In cross-platform validation, the proposed method maintained high accuracy. Consequently, this approach significantly enhances the intelligence and engineering reliability of CAE pre-processing, providing effective technical support for the automated simulation modeling of complex thin-walled components. Full article
Show Figures

Figure 1

31 pages, 26013 KB  
Article
Implementation of an Integrated System for Preventive Maintenance Management and Alerts in Light Vehicles
by Joseph Barreiro-Zambrano, Juan Martinez-Parrales and Roberto López-Chila
Vehicles 2026, 8(5), 100; https://doi.org/10.3390/vehicles8050100 - 1 May 2026
Viewed by 662
Abstract
Inadequate vehicle maintenance management is one of the main causes of road accidents and elevated operating costs in light vehicles. This paper addresses this problem through the development and implementation of a low-cost integrated system for preventive maintenance management and alerts. The device, [...] Read more.
Inadequate vehicle maintenance management is one of the main causes of road accidents and elevated operating costs in light vehicles. This paper addresses this problem through the development and implementation of a low-cost integrated system for preventive maintenance management and alerts. The device, based on an open-hardware architecture (Arduino Mega 2560), integrates Global Positioning System (GPS) and mobile communication (GSM/LTE) modules to monitor distance traveled in real time and notify the user via SMS about the proximity of critical services such as oil changes, brake inspections, and timing-belt replacements. Its technical contribution lies in the integration of non-intrusive virtual ignition, filtered GPS-based odometry, configurable MicroSD-based persistence, and progressive SMS alert logic into a low-cost aftermarket system for conventional vehicles without OBD-II dependence. Experimental validation was conducted in the city of Guayaquil using a 2012 Hyundai Accent. Field tests were carried out in three scenarios: a dense urban route, a peripheral road, and interurban routes. Results showed satisfactory accuracy with a global average percentage error of 3.98% compared to the vehicle’s odometer and 100% effectiveness in sending alerts under the tested conditions (20/20 events; exact 95% binomial confidence interval: 83.2–100.0%). These results provide strong evidence of technical feasibility for the proposed architecture under the tested conditions in a representative single-vehicle proof-of-concept, while broader cross-vehicle validation remains necessary before generalizing the system to the wider diversity of aging fleets. Full article
Show Figures

Figure 1

20 pages, 2765 KB  
Article
Analysis of Pantograph–Catenary Current Collection Performance Under Speed-Upgrading Operating Conditions
by Liqian Wang, Yantao Liang, Dehai Zhang, Xufan Wang, Tong Xing and Yang Song
Vehicles 2026, 8(5), 95; https://doi.org/10.3390/vehicles8050095 - 22 Apr 2026
Viewed by 1977
Abstract
To support the safe operation and technological promotion of existing line speed-up projects, this paper presents an assessment method for pantograph–catenary contact performance under the 200 km/h speed conditions, using the Guangzhou–Shenzhen Lines I and II speed-up projects as representative case studies. Based [...] Read more.
To support the safe operation and technological promotion of existing line speed-up projects, this paper presents an assessment method for pantograph–catenary contact performance under the 200 km/h speed conditions, using the Guangzhou–Shenzhen Lines I and II speed-up projects as representative case studies. Based on the ANCF method, a refined pantograph–catenary coupling dynamic model is established to accurately characterize the large deformation and geometric nonlinear behavior of the catenary system. Model validation is achieved using actual measurement data from the CR400AF train. Based on this model, systematic simulation analyses were conducted to evaluate the current collection performance of four mainstream train models—CR300AF, CR400BF, CRH380A, and CRH380B—under both single-unit and double-unit operation conditions. Results indicate that dynamic contact force metrics for pantograph–catenary interactions meet all limit requirements specified in the Technical Specifications for Dynamic Acceptance of High-Speed Railway Projects under all operating conditions. This demonstrates that the pantograph–catenary system on the analyzed Guangzhou–Shenzhen Line exhibits excellent dynamic stability and safety under the targeted speed-up scheme, providing simulation-based justification for implementing the speed enhancement project. Full article
(This article belongs to the Special Issue Planning and Operations for Modern Railway Transport Systems)
Show Figures

Figure 1

Previous Issue
Next Issue
Back to TopTop
