Journal Description
Machines
Machines
is an international, peer-reviewed, open access journal on machinery and engineering, published monthly online by MDPI. The International Federation for the Promotion of Mechanism and Machine Science (IFToMM) is affiliated with Machines and its members receive a discount on the article processing charges.
- Open Access— free for readers, with article processing charges (APC) paid by authors or their institutions.
- High Visibility: indexed within Scopus, SCIE (Web of Science), Inspec, and other databases.
- Journal Rank: JCR - Q2 (Engineering, Mechanical) / CiteScore - Q1 (Control and Optimization)
- Rapid Publication: manuscripts are peer-reviewed and a first decision is provided to authors approximately 15.9 days after submission; acceptance to publication is undertaken in 2.9 days (median values for papers published in this journal in the first half of 2026).
- Recognition of Reviewers: Reviewers whose reports are timely and of high quality receive an APC discount voucher for a future publication in an MDPI journal. Become a reviewer.
- Journal Cluster of Mechanical Manufacturing and Automation Control: Aerospace, Automation, Drones, Journal of Manufacturing and Materials Processing, Machines, Robotics and Technologies.
- Companion journals for Machines include: Industries and Precision.
Impact Factor:
3.0 (2025);
5-Year Impact Factor:
2.9 (2025)
Latest Articles
Machine Learning-Based Fault Classification for Intelligent Condition Monitoring in Industrial Production Systems
Machines 2026, 14(10), 1123; https://doi.org/10.3390/machines14101123 - 29 Sep 2026
Abstract
Industrial production systems require intelligent maintenance solutions to minimize unplanned downtime, improve reliability, and support data-driven decision making. This study presents a machine learning framework for condition monitoring and fault classification in industrial production systems. The framework is evaluated using an AI4I-derived synthetic
[...] Read more.
Industrial production systems require intelligent maintenance solutions to minimize unplanned downtime, improve reliability, and support data-driven decision making. This study presents a machine learning framework for condition monitoring and fault classification in industrial production systems. The framework is evaluated using an AI4I-derived synthetic dataset comprising 10,000 production events characterized by operational sensor measurements and machine failure indicators. An exploratory analysis is first conducted to examine data distributions, failure patterns, and relationships among operational variables. Subsequently, four classification models (Logistic Regression, Random Forest, Histogram-Based Gradient Boosting, and a Multilayer Perceptron (MLP) neural network) are developed and comparatively evaluated. The results show that nonlinear models significantly outperform the Logistic Regression baseline, with Random Forest, Histogram-Based Gradient Boosting, and MLP achieving very high classification performance. The findings suggest that interactions among operational variables contribute substantially to the fault classification task and are more effectively captured by nonlinear learning approaches than by linear models using the original feature set. Overall, the study provides a benchmark-style comparative evaluation of representative machine learning classifiers for fault classification on an AI4I-derived synthetic dataset. The findings primarily illustrate classifier behavior under controlled synthetic conditions and provide a basis for future validation using real industrial data and operational maintenance environments.
Full article
(This article belongs to the Special Issue Digital Twins and Intelligent Systems for Condition-Based Industrial Maintenance)
Open AccessArticle
Robust Cooperative Control for Heavy-Haul Group Trains via Tube-MPC Considering Wheel–Rail Adhesion
by
Huazhen Yu, Wen Zhao, Andrea D’Ariano, Ruifei An, Peng Xu and Anzheng Lai
Machines 2026, 14(10), 1122; https://doi.org/10.3390/machines14101122 - 29 Sep 2026
Abstract
Heavy-haul railways are mainly located in mountainous regions, where wheel–rail adhesion is susceptible to variations in rail-surface conditions, posing challenges to the cooperative operation control of heavy-haul group trains (HHGTs). This paper develops an adhesion-dependent Tube-based model predictive control (Tube-MPC) method for HHGTs
[...] Read more.
Heavy-haul railways are mainly located in mountainous regions, where wheel–rail adhesion is susceptible to variations in rail-surface conditions, posing challenges to the cooperative operation control of heavy-haul group trains (HHGTs). This paper develops an adhesion-dependent Tube-based model predictive control (Tube-MPC) method for HHGTs by incorporating adhesion conditions into disturbance set construction, robust error Tube design, and nominal constraint tightening. A control-oriented longitudinal dynamics model retaining position-dependent gradient resistance is established to describe the motion of heavy-haul trains. Adhesion-dependent limits on traction and braking forces are imposed as input constraints, while adhesion uncertainty is modeled as a bounded equivalent acceleration disturbance arising from adhesion-induced force mismatch. An ancillary feedback controller is employed to regulate actual-nominal state deviations and ensure robust constraint satisfaction. Simulations are conducted using parameters of approximately 5000 t heavy-haul trains and a real railway gradient profile under dry, wet, and rainy or snowy rail-surface conditions. The results demonstrate that, when the actual disturbance remains within the design bound, the trajectories of all following trains remain within the error Tube. Compared with PID and standard MPC, the proposed approach improves speed coordination and spacing regulation, indicating its effectiveness for the cooperative operation of HHGTs under complex wheel–rail adhesion conditions.
Full article
(This article belongs to the Special Issue Artificial Intelligence-Enabled Vehicle Systems: Modeling, Control Optimization and Fault Diagnosis)
Open AccessArticle
The Intelligent Crusher: A Reinforcement Learning Framework for Sensor-Fused Microwave-Assisted Comminution: Design and Simulation-Based Validation
by
George Chantoumakos, Georgios Tsimiklis, Angelos P. Markopoulos, Angelos Amditis and Fotios Konstantinidis
Machines 2026, 14(10), 1121; https://doi.org/10.3390/machines14101121 - 29 Sep 2026
Abstract
►▼
Show Figures
Comminution is the most energy-intensive stage of mineral processing, and microwave-assisted comminution (MAC) can reduce grinding energy by selectively heating microwave-absorbing minerals within transparent gangue, generating thermal microcracks that improve liberation. MAC performance, however, depends on the ore mineralogy and surface, which fixed-parameter
[...] Read more.
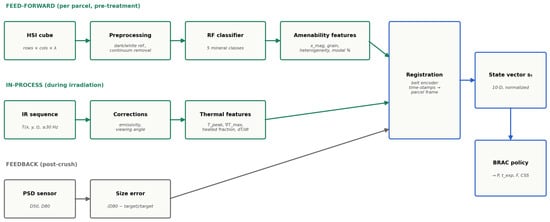
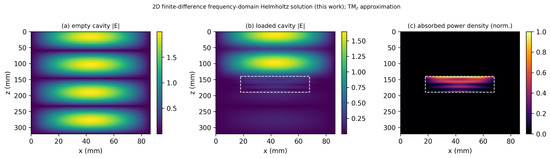
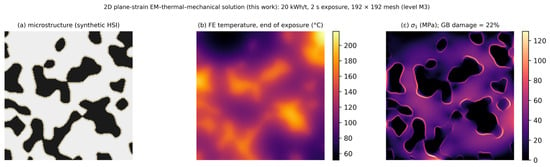
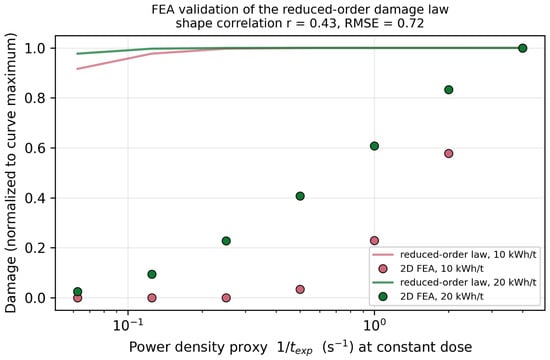
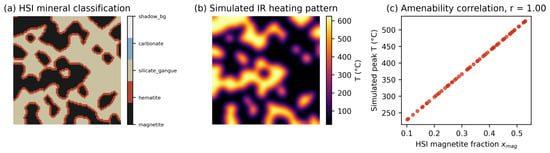
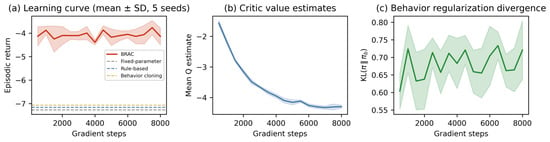
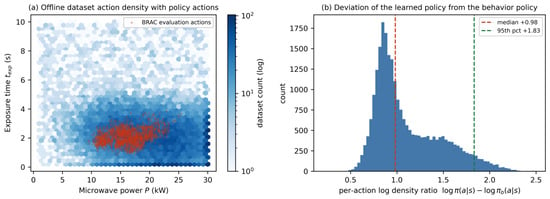
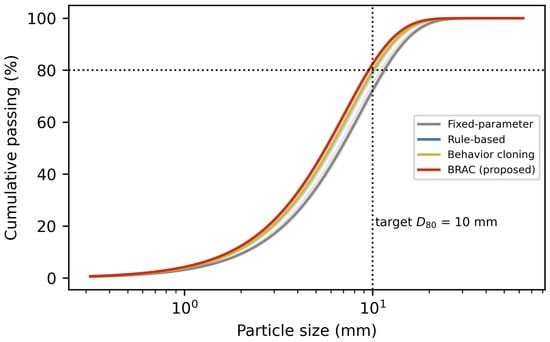
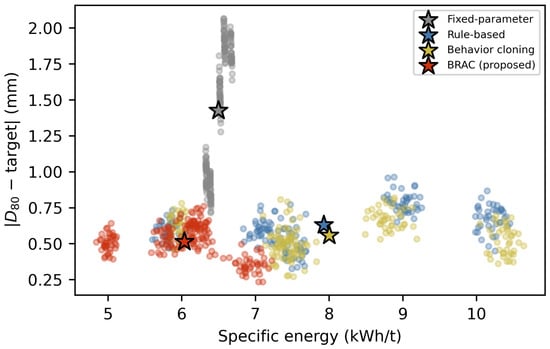
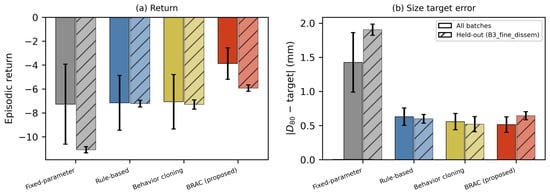
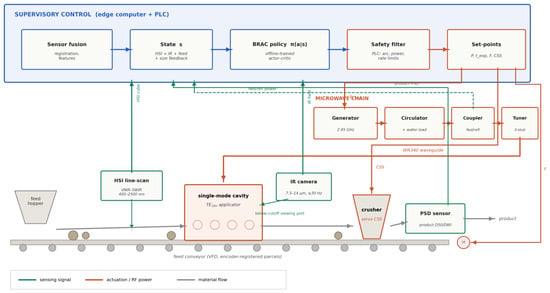
Comminution is the most energy-intensive stage of mineral processing, and microwave-assisted comminution (MAC) can reduce grinding energy by selectively heating microwave-absorbing minerals within transparent gangue, generating thermal microcracks that improve liberation. MAC performance, however, depends on the ore mineralogy and surface, which fixed-parameter operation cannot accommodate. An integrated mechatronic “intelligent crusher” is presented unifying actuation (microwave source, feed system, adjustable crusher geometry), sensing (thermal infrared and hyperspectral imaging, HSI), and control (offline reinforcement learning). HSI-derived mineralogical features and infrared thermal features form the state of a behavior-regularized actor–critic (BRAC) controller trained offline on logged operating data to adjust the power, exposure, feed rate, and crusher setting. A two-dimensional coupled electromagnetic–thermal–mechanical finite-element study underpins the process model. It is executed with temperature-independent dielectric properties in a single staggered coupling pass, and so calibrates the damage law qualitatively rather than predicting stress quantitatively. It reproduces cracking thresholds from the literature and shows that thermal gradients decay with exposure time as (1 + t/ )−0.57, so that damage at a constant dose falls from 0.63 to 0.02 as exposure lengthens from 0.25 to 16 s. On this basis, the phenomenological damage law, which had been exposure-insensitive, is corrected. On the FEA-calibrated simulator, the BRAC policy reduces the mean size targeting error by 62% (1.43 to 0.54 mm) and the total specific energy by 4.2% (6.50 to 6.22 kWh/t), averaged over five training seeds, relative to fixed-parameter operation, outperforms rule-based and behavior-cloning baselines, and generalizes to a simulated ore batch excluded from the training. The framework establishes a validated control architecture for adaptive MAC ahead of three-dimensional model extension and experimental deployment.
Full article

Figure 1
Open AccessArticle
Redundant-Motion Coordination and Base Disturbance Suppression of a 6R1P Free-Floating Space Manipulator Based on Deep Reinforcement Learning
by
Jian Zhao, Tongtong Li, Zelin Yang, Shize Qin, Jiaqi Duan, Hao Zhang and Yanbo Wang
Machines 2026, 14(10), 1120; https://doi.org/10.3390/machines14101120 - 29 Sep 2026
Abstract
Free-floating space manipulators are strongly coupled systems in which manipulator motion affects spacecraft base motion through momentum exchange, making simultaneous end-effector control and disturbance suppression challenging. This work investigates how an additional actuated prismatic degree of freedom influences whole-arm coordination in a 6R1P
[...] Read more.
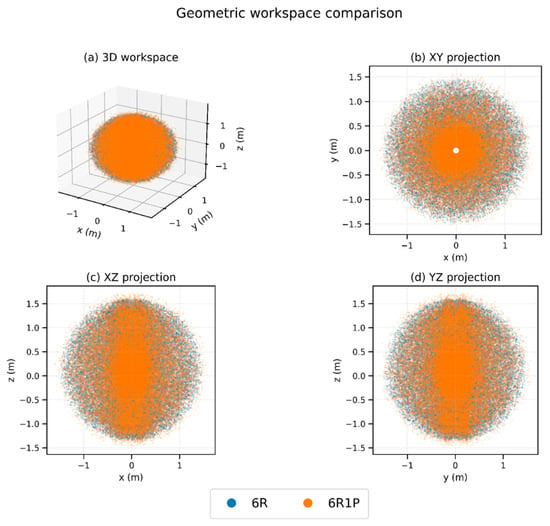
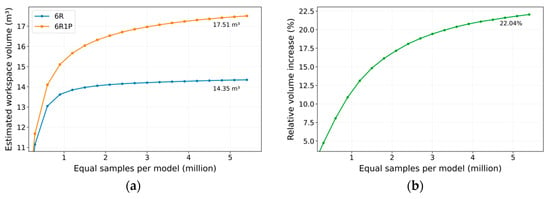
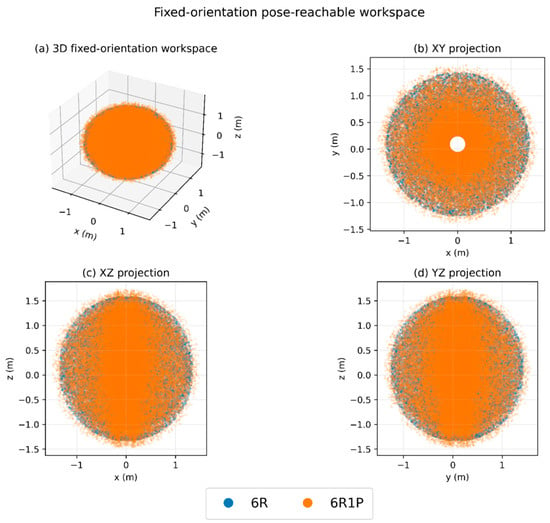
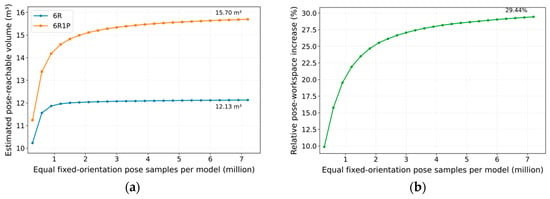
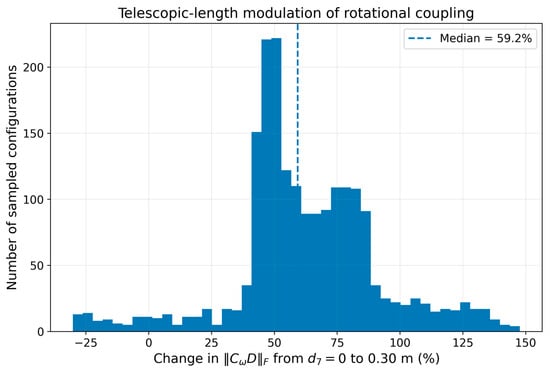
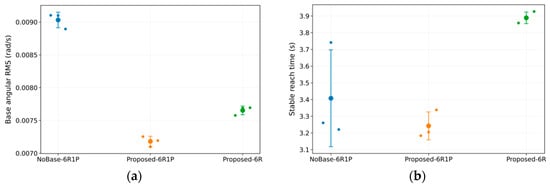
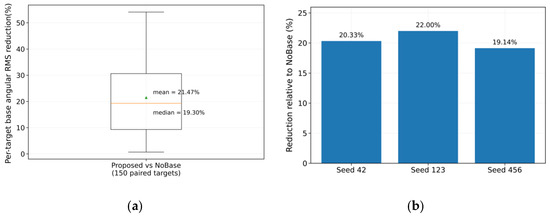
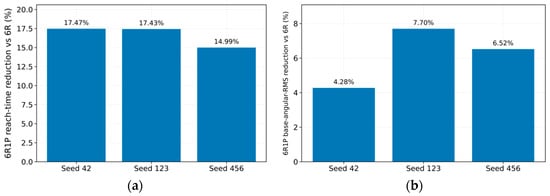
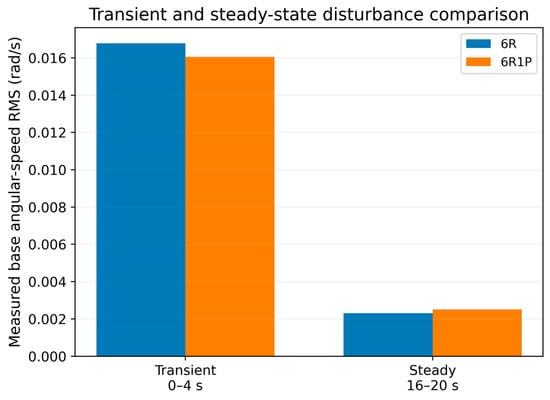
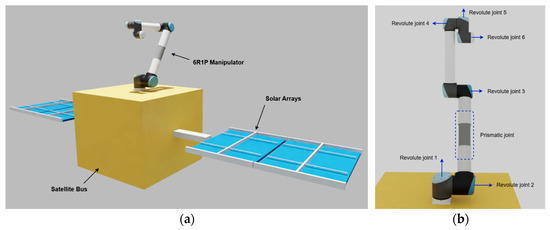
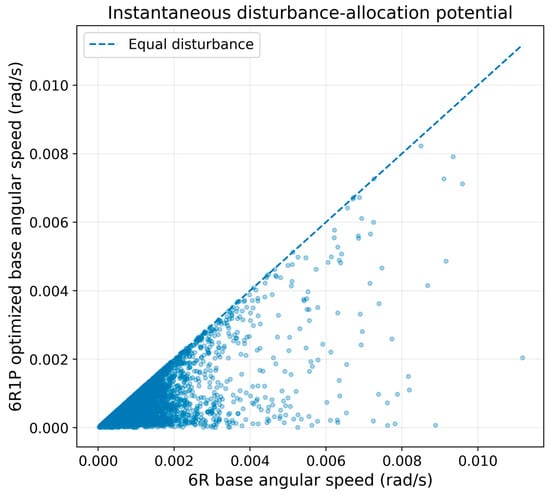
Free-floating space manipulators are strongly coupled systems in which manipulator motion affects spacecraft base motion through momentum exchange, making simultaneous end-effector control and disturbance suppression challenging. This work investigates how an additional actuated prismatic degree of freedom influences whole-arm coordination in a 6R1P free-floating space manipulator. Compared with a fixed-length 6R configuration, the prismatic joint enlarges the feasible motion space and introduces an additional motion-allocation direction for full-pose tasks under generalized-Jacobian constraints. A proximal policy optimization (PPO)-based controller is developed for full-pose reaching with spacecraft-motion-aware objectives. Simulation results show that the 6R1P configuration improves reaching performance and reduces spacecraft reaction compared with the locked-prismatic 6R baseline. Trajectory-level dynamic reconstruction further reveals that the disturbance reduction is not caused by direct cancellation from the prismatic joint itself, but mainly by configuration-dependent redistribution of revolute-joint motions and enhanced mutual cancellation among their reaction contributions. These results demonstrate that telescopic redundancy provides a mechanism for coordinated motion allocation in free-floating manipulation, enabling learned policies to exploit additional degrees of freedom for improved task execution and reduced spacecraft disturbance.
Full article
(This article belongs to the Special Issue Smart Structures and Applications in Aerospace Engineering)
►▼
Show Figures

Figure 1
Open AccessArticle
Rolling-Bearing Remaining Useful Life Prediction Using Adaptive Fusion-VHI and Differential Gaussian Process Regression
by
Sangang Yao, Yijie Li, Haichao Cai and Hongfan Yang
Machines 2026, 14(10), 1119; https://doi.org/10.3390/machines14101119 - 29 Sep 2026
Abstract
Accurate remaining useful life (RUL) prediction of rolling bearings is important for condition-based maintenance. This study proposes an interpretable rolling RUL prediction framework integrating adaptive multidomain degradation representation, prognostic-stage localization, and differential Gaussian process regression (Diff-GPR). A 48-dimensional feature pool is extracted from
[...] Read more.
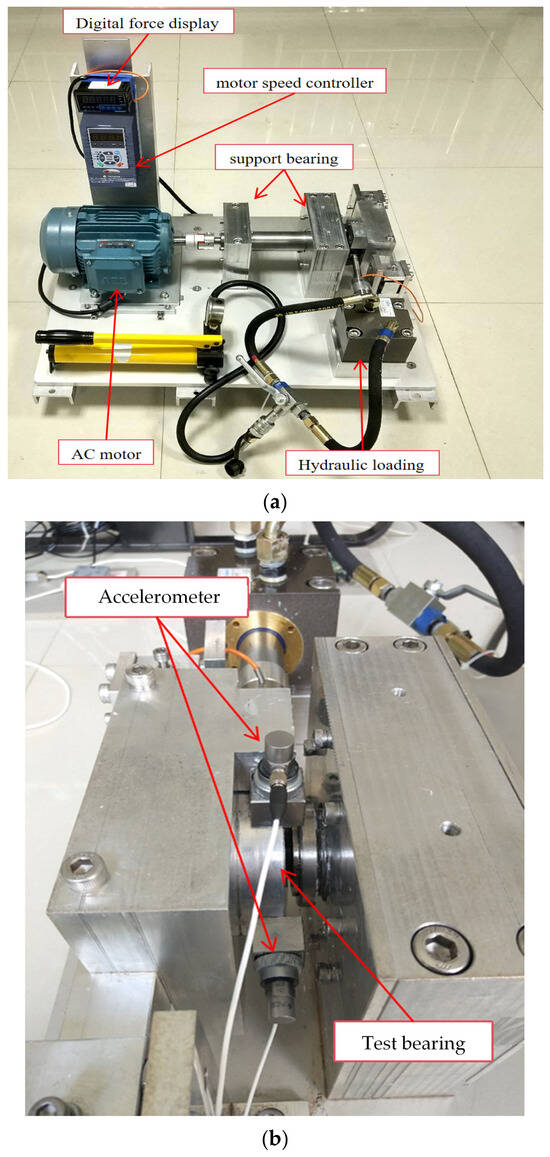
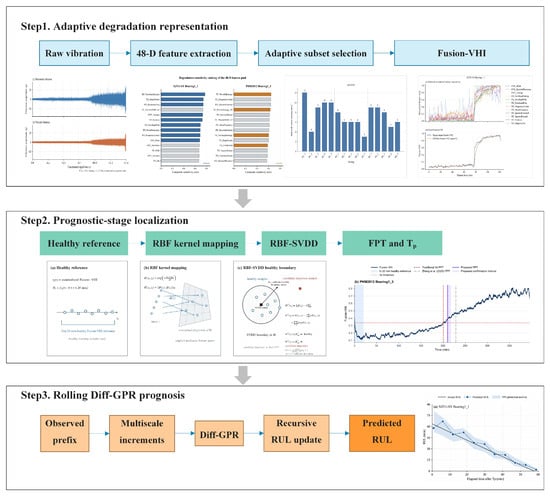
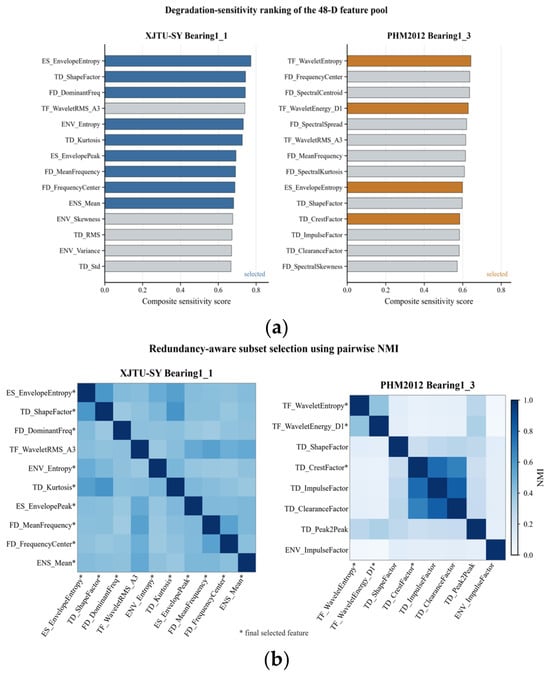
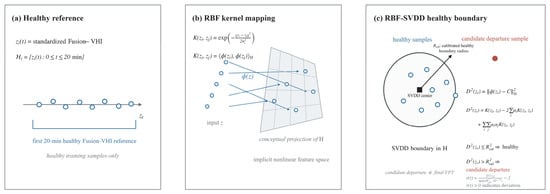
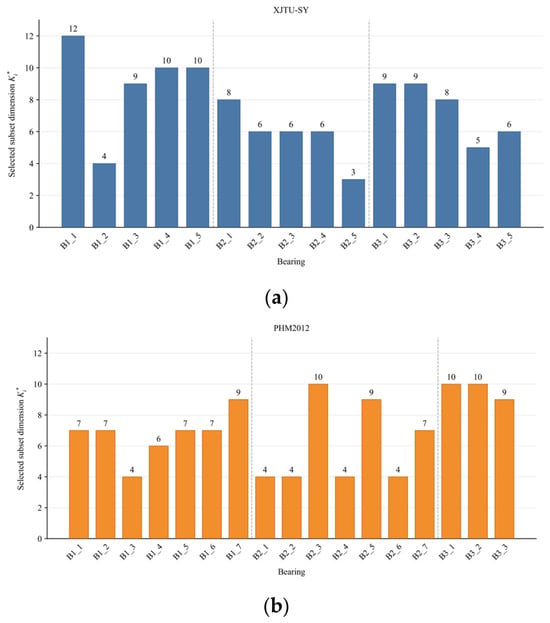
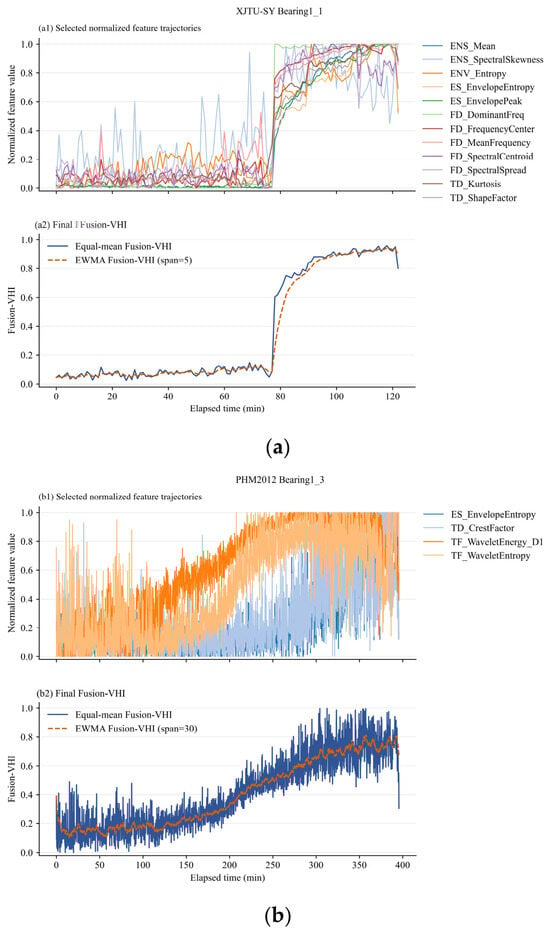
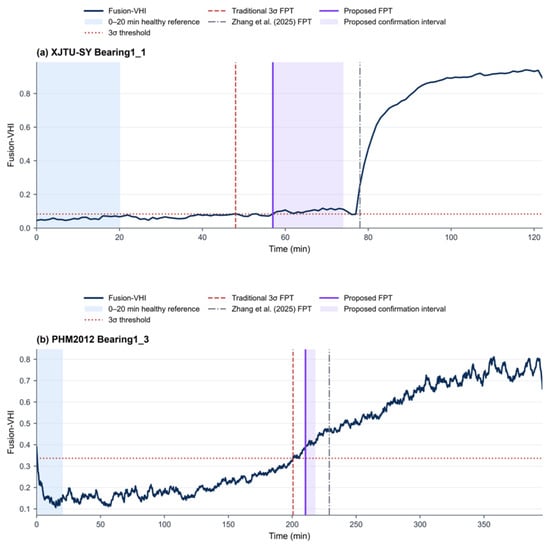
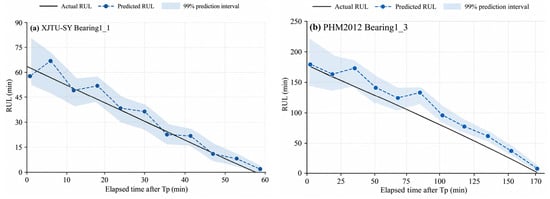
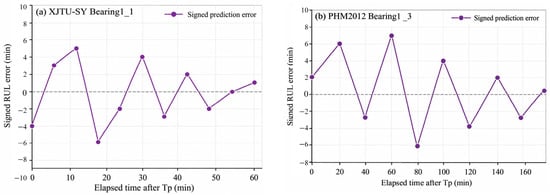
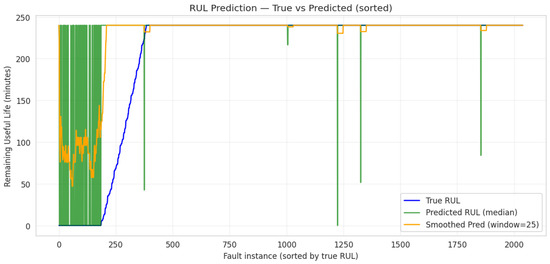
Accurate remaining useful life (RUL) prediction of rolling bearings is important for condition-based maintenance. This study proposes an interpretable rolling RUL prediction framework integrating adaptive multidomain degradation representation, prognostic-stage localization, and differential Gaussian process regression (Diff-GPR). A 48-dimensional feature pool is extracted from six vibration domains, and bearing-specific degradation-sensitive subsets are selected using monotonicity, trendability, robustness, and redundancy criteria. The retained features are directionally aligned, percentile-normalized, equally fused, and smoothed to construct a fusion virtual health indicator (Fusion-VHI). A two-stage localization strategy identifies sustained degradation onset and the subsequent prediction-ready point, after which Diff-GPR models multiscale degradation increments and recursively updates failure time and RUL. The framework was evaluated on all 15 bearings from the Xi’an Jiaotong University–Changxing Sumyoung Technology (XJTU-SY) dataset and all 17 bearings from the 2012 Prognostics and Health Management (PHM2012)/PRONOSTIA dataset. Full final rolling prediction coverage was achieved, with mean absolute error/root-mean-square error (MAE/RMSE) values of 6.33/7.26 min on XJTU-SY and 6.03/6.98 min on PHM2012, and overall values of 6.17/7.11 min. Representative 99% predictive intervals achieved 100% prediction-interval coverage probability, while signed-error analysis identified 13 early and 19 late final predictions with an overall mean signed error of +1.77 min.
Full article
(This article belongs to the Section Machines Testing and Maintenance)
►▼
Show Figures

Figure 1
Open AccessArticle
Comparative Analysis of Micro-Machining of 316L Stainless Steel Fabricated by Laser Powder Bed Fusion, Laser-Wire Directed Energy Deposition and Conventional Methods
by
Ramazan Hakkı Namlu, Ahmed Abotoor, Ahmad Wael Alshaer and Zekai Murat Kılıç
Machines 2026, 14(10), 1118; https://doi.org/10.3390/machines14101118 - 29 Sep 2026
Abstract
The demand for miniature 316L stainless steel components in critical sectors is increasingly met by additive manufacturing (AM); however, due to the increasing applications of 316L in advanced manufacturing industries, there is a need to identify the machinability performance for 316L based on
[...] Read more.
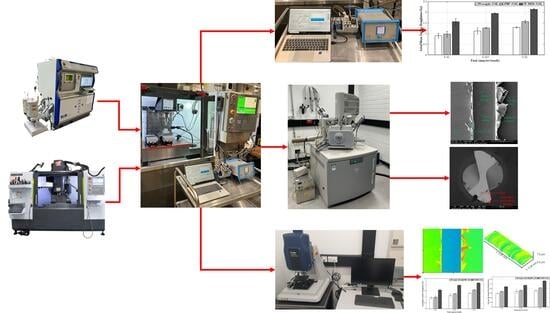
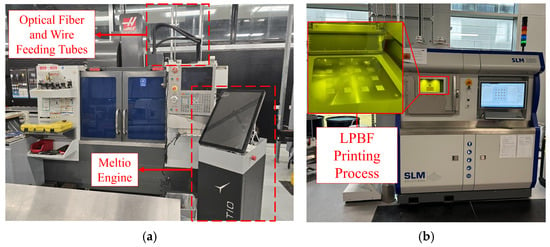
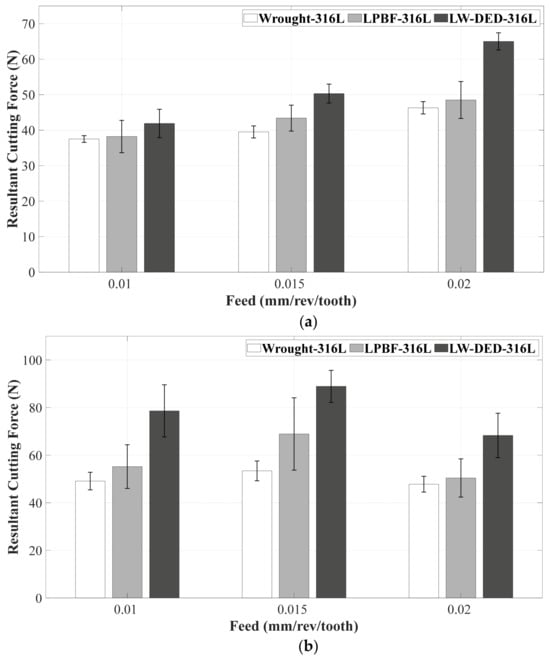
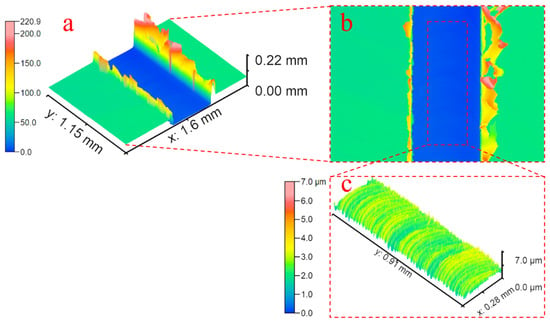
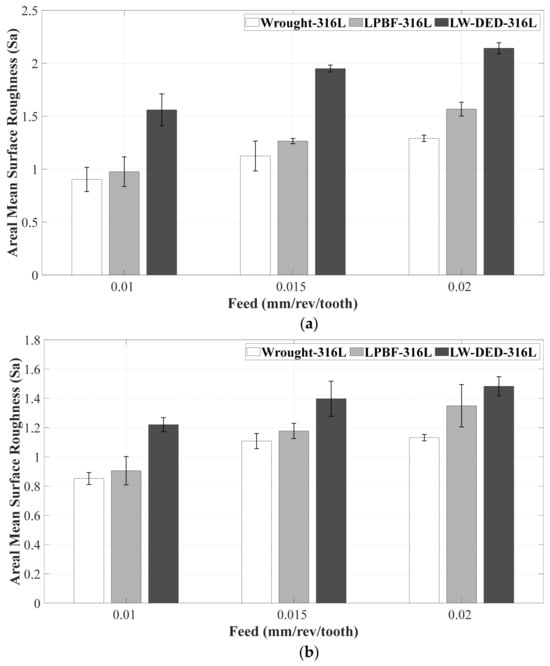
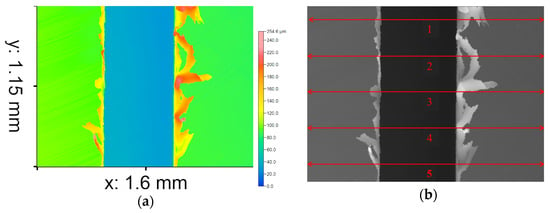
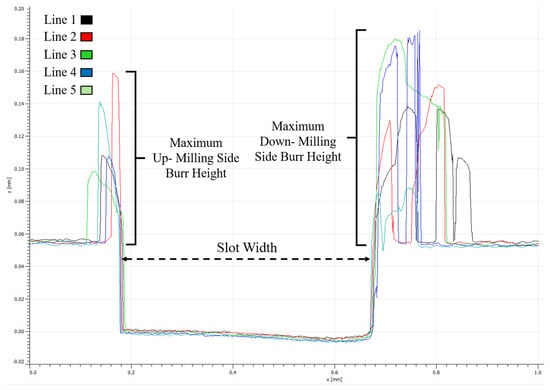
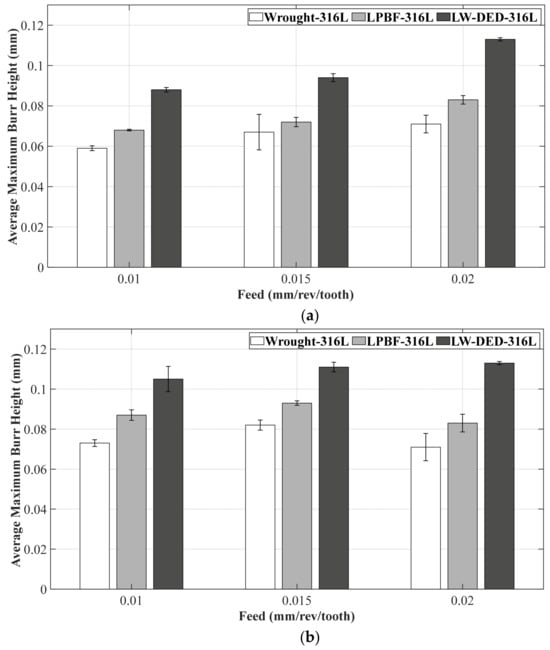
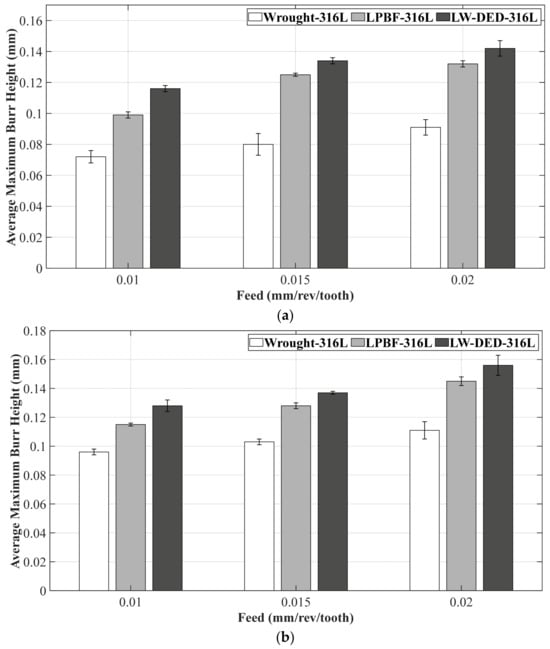
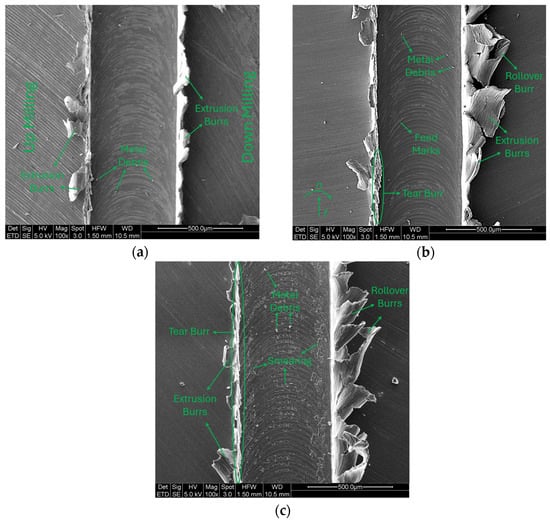
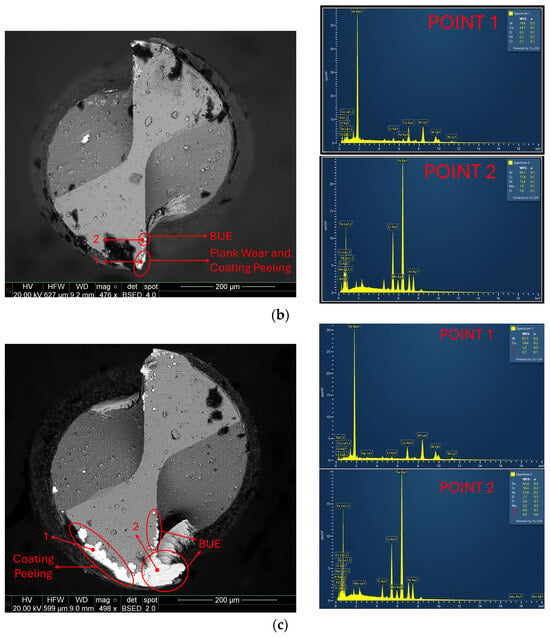
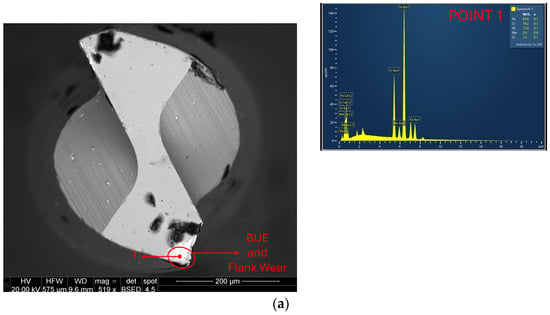
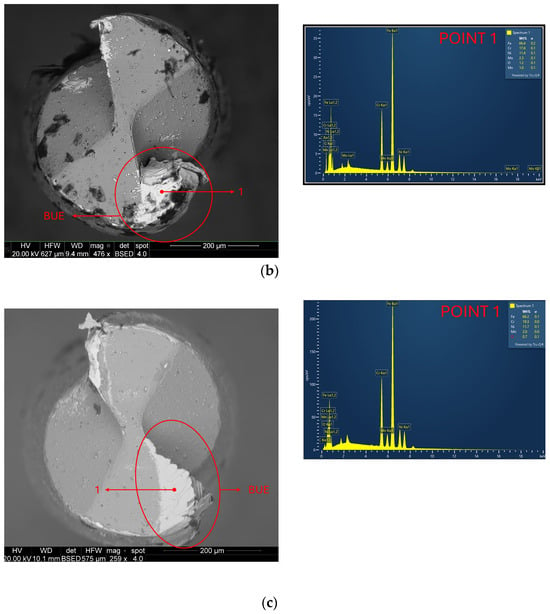
The demand for miniature 316L stainless steel components in critical sectors is increasingly met by additive manufacturing (AM); however, due to the increasing applications of 316L in advanced manufacturing industries, there is a need to identify the machinability performance for 316L based on the fabrication techniques for addressing challenges. This study investigates the micro-machining performance of 316L material fabricated via Laser Powder Bed Fusion (LPBF), Laser-Wire Directed Energy Deposition (LW-DED), and conventional (wrought) methods. Results reveal wrought 316L exhibits superior machinability, yielding the lowest cutting forces, surface roughness, burr heights, and tool wear. Compared to the wrought baseline, average cutting forces increased by 10.5% for LPBF and 41.4% for LW-DED. Areal surface roughness deteriorated by 12.3% for LPBF and 52.1% for LW-DED. Average maximum down-milling burr heights were 35.6% and 48.8% higher for LPBF-316L and LW-DED-316L, respectively, than for wrought 316L. The observed ranking of machining responses was associated with the specific material conditions investigated. SEM observations and microhardness measurements indicate morphological and hardness differences among the specimens, which may have contributed to the measured differences in cutting force, surface roughness, burr formation, and qualitative tool-condition observations. As a result, process-induced specimen variations fundamentally govern the micro-machinability of AM 316L, offering critical insights for optimizing post-processing operations.
Full article
(This article belongs to the Special Issue Monitoring and Control of Additive, Machining, and Hybrid Manufacturing Processes)
►▼
Show Figures

Graphical abstract
Open AccessReview
Robots for Bilateral Upper Limb Rehabilitation in Post-Stroke Patients: A State-of-the-Art Review
by
Jesús Eduardo Cortés Flores, César Humberto Guzmán-Valdivia, Andrés Blanco Ortega, Arturo Abundez Pliego, Enrique Alcudia-Zacarías and Héctor Ramón Azcaray Rivera
Machines 2026, 14(10), 1117; https://doi.org/10.3390/machines14101117 - 29 Sep 2026
Abstract
Bilateral robotic rehabilitation has emerged as a technological approach for promoting coordinated upper-limb training after stroke. This state-of-the-art review critically analyzes bilateral upper-limb rehabilitation robots with emphasis on mechanical architecture, actuation and transmission, bilateral interaction modalities, control strategies, assistance modes, and validation evidence.
[...] Read more.
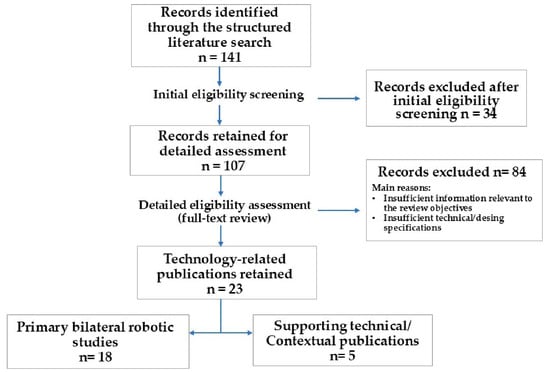
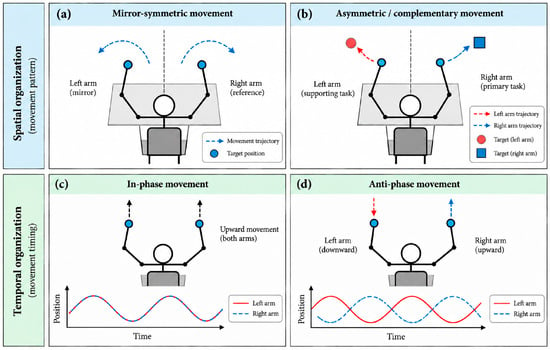
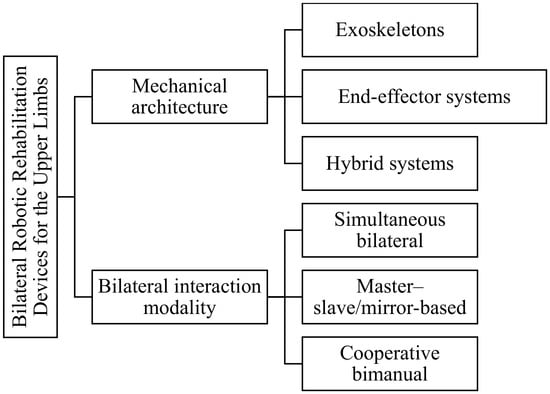
Bilateral robotic rehabilitation has emerged as a technological approach for promoting coordinated upper-limb training after stroke. This state-of-the-art review critically analyzes bilateral upper-limb rehabilitation robots with emphasis on mechanical architecture, actuation and transmission, bilateral interaction modalities, control strategies, assistance modes, and validation evidence. A structured literature search covering 2010 to 8 July 2026 identified 141 records; 23 technology-related publications were retained for the state-of-the-art analysis, comprising 18 primary bilateral robotic studies and 5 supporting technical/contextual publications. The reviewed systems were organized according to a hierarchical framework distinguishing end-effector, exoskeleton, and hybrid architectures from simultaneous bilateral, master–slave/mirror-based, and cooperative bimanual interaction modalities. The evidence indicates that end-effector systems favor mechanical simplicity and adaptable workspaces, whereas exoskeletons provide more direct joint-level control at the cost of greater alignment and mechanical complexity. Control approaches increasingly incorporate impedance, admittance, assist-as-needed, and bio-signal-based strategies to improve compliant interaction and adapt assistance to user contribution. However, many advanced systems remain supported primarily by engineering validation or experiments involving healthy participants, while direct post-stroke clinical validation is comparatively limited. Future development should therefore prioritize clinically validated adaptive assistance, control strategies capable of accommodating asymmetric bilateral contribution, and safe, usable, and affordable systems suitable for clinical and home-based rehabilitation.
Full article
(This article belongs to the Special Issue Advanced Robotic and Mechatronic Systems for Physical Rehabilitation and Assistive Technologies)
►▼
Show Figures

Figure 1
Open AccessArticle
Material-Aware First-Grasp Target Preselection for Mixed Rigid-Deformable Technical-Waste Mock-Ups
by
Yongzhuo Liu, Jiangmei Zhang, Haolin Liu and Yongfa Mi
Machines 2026, 14(10), 1116; https://doi.org/10.3390/machines14101116 - 29 Sep 2026
Abstract
Robotic sorting of mixed rigid–deformable technical waste requires the selection of a graspable first target while minimizing disturbance to surrounding objects. This paper proposes a lightweight material-conditioned target-preselection method for cluttered RGB-D scenes. Object instances are detected using YOLO26n and segmented using SAM2-B,
[...] Read more.
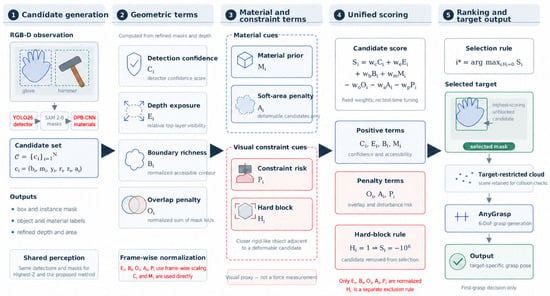
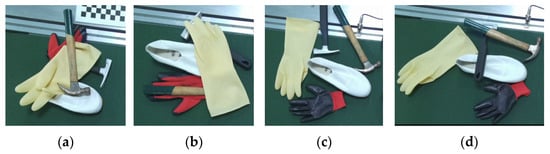
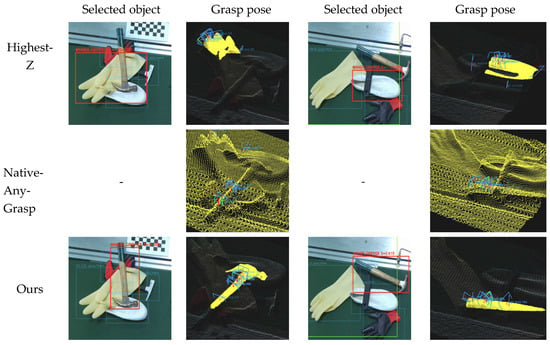
Robotic sorting of mixed rigid–deformable technical waste requires the selection of a graspable first target while minimizing disturbance to surrounding objects. This paper proposes a lightweight material-conditioned target-preselection method for cluttered RGB-D scenes. Object instances are detected using YOLO26n and segmented using SAM2-B, while their material categories are predicted using DPB-CNN. Depth-consistency filtering is subsequently applied to refine the candidate masks. Each candidate is evaluated according to geometric accessibility and local overlap, while visually inferred rigid-over-deformable relations are used to penalize or exclude deformable objects constrained by rigid-like objects. AnyGrasp generates a 6-DoF grasp pose using dense target points together with a downsampled workspace cloud retained for collision checking. Experiments were conducted on a UR5 platform using 40 predefined layouts covering four representative rigid–deformable interaction patterns, with three trials per method for each layout. The proposed method achieved a target selection accuracy (TSA) of 86.7%, a first-grasp success rate (FSR) of 80.8%, and a severe-disturbance rates (SDR) of 8.3%. After Holm correction, TSA was significantly higher than for both baselines, and SDR was significantly lower than for Native-AnyGrasp. The observed FSR improvements did not reach the corrected significance threshold. These results support improved first-grasp decision-making and reduced disturbance relative to Native-AnyGrasp in the evaluated technical-waste mock-up scenarios.
Full article
(This article belongs to the Special Issue Advances and Challenges in Robotic Manipulation)
►▼
Show Figures

Figure 1
Open AccessArticle
Position-Dependent Vibration Response and Inverse Design of X-Type Nonlinear Supports for a Cargo–Vehicle–Road Coupled System
by
Jinyue Kang, Dapeng Zhu and Yuanyuan Wang
Machines 2026, 14(10), 1115; https://doi.org/10.3390/machines14101115 - 28 Sep 2026
Abstract
Cargo items at different longitudinal positions experience different local base excitations because of vehicle-body bounce and pitch, creating position-dependent demands on vibration isolation and support stroke. This study presents a response-guided equivalent-design framework that links critical-position identification to the selection of nonlinear support
[...] Read more.
Cargo items at different longitudinal positions experience different local base excitations because of vehicle-body bounce and pitch, creating position-dependent demands on vibration isolation and support stroke. This study presents a response-guided equivalent-design framework that links critical-position identification to the selection of nonlinear support characteristics represented by an equivalent force model for X-type cargo supports. A coupled model comprising prescribed stochastic road inputs, linear tire stiffness and damping, a four-degree-of-freedom half-car subsystem, and five vertically supported cargo masses of 2000 kg each is established. Cargo acceleration, relative support displacement, interaction force, and energy-related indicators are evaluated. Under the nominal condition used for design-target extraction, P5 is identified as the critical position, with a dominant local-base frequency of 2.3994 Hz and an RMS-equivalent displacement amplitude of 15.339 mm. These response characteristics, together with prescribed design constraints, guide the selection of equivalent support properties. The support force law includes basic stiffness, delayed hardening, a displacement-activated limiting term, displacement-dependent damping, and regularized friction. In the nominal system-level comparison, the low-frequency-compliant X-type scheme reduced the maximum P5 stroke from 35.68 mm to 31.81 mm relative to the feasible low-frequency linear reference, accompanied by small increases in acceleration and interaction-force RMS. Under the investigated perturbed conditions, the grouped X-type configuration reduced the largest P5 stroke from 56.05 mm to 47.83 mm relative to the linear reference; however, it still exceeded the prescribed 40 mm limit. Further parameter optimization, independent benchmark comparison, and experimental validation are required before engineering feasibility can be established.
Full article
(This article belongs to the Section Vehicle Engineering)
Open AccessArticle
Explicit Reduced-Order Modeling and Data-Efficient Physics-Informed Inverse Design of Laminated Non-Pneumatic Tires
by
Weidong Liu, Jialiang Wang, Qiushi Zhang, Jun Xing and Changzheng Li
Machines 2026, 14(10), 1114; https://doi.org/10.3390/machines14101114 - 28 Sep 2026
Abstract
Efficient forward and inverse design of laminated non-pneumatic tires requires repeated evaluation of their load-bearing and tire–ground contact responses. The high-fidelity laminated beam–grounding analysis (LB-GA) formulation captures the coupled band and spoke mechanics but requires iterative solution of 18 differential equations with unknown
[...] Read more.
Efficient forward and inverse design of laminated non-pneumatic tires requires repeated evaluation of their load-bearing and tire–ground contact responses. The high-fidelity laminated beam–grounding analysis (LB-GA) formulation captures the coupled band and spoke mechanics but requires iterative solution of 18 differential equations with unknown regional boundaries. This study derives explicit reduced-order relations for vertical stiffness and average contact pressure by combining laminated curved-beam mechanics with double-sided compression-ring theory. Joint fitting to 500 high-fidelity LB-GA solutions yields the empirical screening criterion . In an additional set of 5000 independently generated cases spanning the investigated design and material domain, 97.68% of the cases satisfying this criterion have a maximum response error no greater than 10%. The explicit relations are subsequently used as a domain-masked mechanics constraint in a multi-fidelity physics-informed neural network trained with independent high-fidelity labels. With labels, the model gives stiffness and pressure NRMSEs of 4.47% and 4.68%, whereas a data-driven model using labels gives 5.00% and 8.37%. Model-preparation time decreases from 220.1 to 32.5 h. Multiobjective inverse design, a newly manufactured-tire experiment, and six reconstructed finite-element designs produce validation errors below 10%. The framework therefore enables accurate tire design with substantially fewer high-fidelity numerical labels.
Full article
(This article belongs to the Section Vehicle Engineering)
►▼
Show Figures

Graphical abstract
Open AccessArticle
A Parametric Sensor Digital Twin Framework for Virtual Benchmarking of Mems Accelerometers in Edge-Iiot Pump Diagnostics
by
Alexey Savostin, Kayrat Koshekov, Amandyk Tuleshov, Yerkebulan Tuleshov, Magzhan Kanapiya and Anatoliy Prosselkov
Machines 2026, 14(10), 1113; https://doi.org/10.3390/machines14101113 - 28 Sep 2026
Abstract
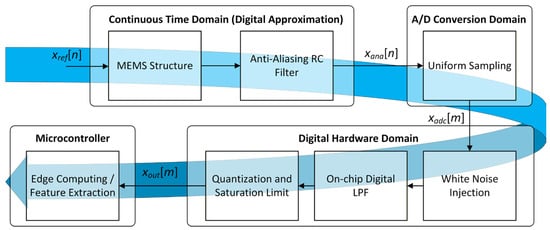
The deployment of autonomous predictive vibration-based diagnostics in Edge-IIoT requires balancing the cost of Micro-Electro-Mechanical System (MEMS) accelerometers against their metrological limitations. This study proposes a parametric Sensor Digital Twin (SDT) framework for virtual benchmarking of measurement chains at the hardware-software co-design stage.
[...] Read more.
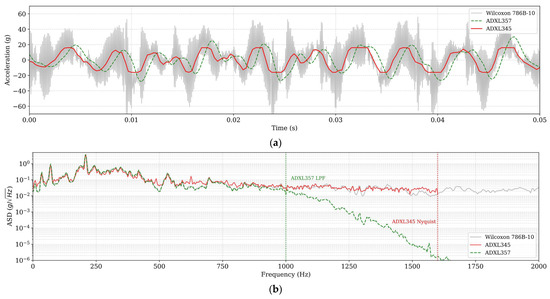
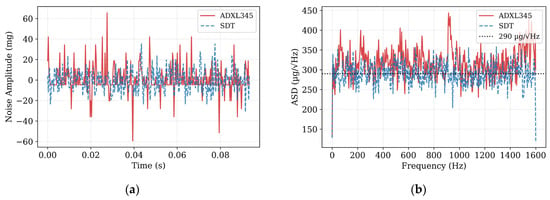
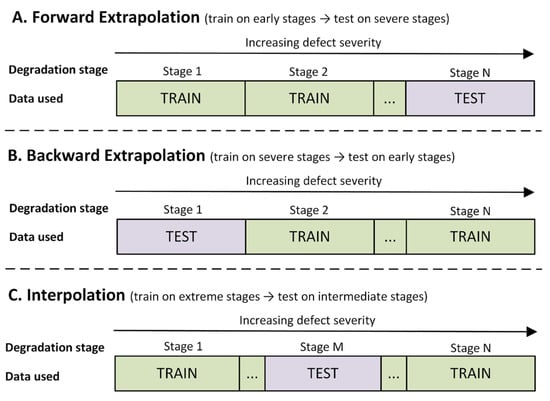
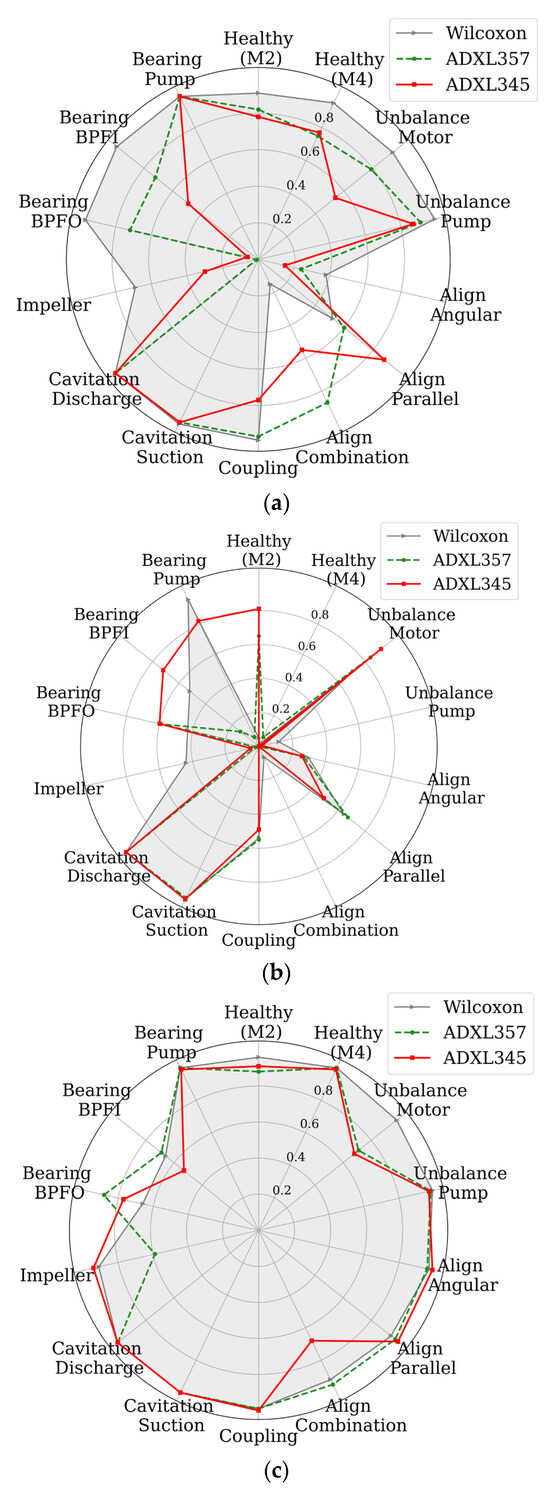
The deployment of autonomous predictive vibration-based diagnostics in Edge-IIoT requires balancing the cost of Micro-Electro-Mechanical System (MEMS) accelerometers against their metrological limitations. This study proposes a parametric Sensor Digital Twin (SDT) framework for virtual benchmarking of measurement chains at the hardware-software co-design stage. The SDT model emulates mechanical and electrical filtering, aliasing, noise, and quantization; its fidelity was validated experimentally using a physical ADXL345 sensor, with an RMS noise error of 8.56%. Virtual profiles of the commercial ADXL345 and ADXL357 sensors were generated using the reference NLN-EMP centrifugal pump dataset acquired with a Wilcoxon 786B-10 piezoelectric accelerometer. Their diagnostic performance was evaluated using eight diagnostic features and five heterogeneous machine-learning algorithms under interpolation, forward extrapolation, and backward extrapolation scenarios across fault severity levels. In the interpolation scenario, the ADXL345 and ADXL357 profiles achieved Macro F1-scores of 0.8999 and 0.8947, respectively, compared with 0.9567 for the reference measurement chain. In the forward extrapolation scenario, the ADXL357 profile achieved a Macro F1-score of 0.7171, compared with 0.6768 for the reference measurement chain. The results confirm that the SDT can support sensor hardware selection through virtual benchmarking, while the considered MEMS accelerometers provide comparable diagnostic performance in the evaluated scenarios when a representative training dataset is available.
Full article
(This article belongs to the Section Machines Testing and Maintenance)
►▼
Show Figures

Figure 1
Open AccessArticle
System Integration and Sea Trials of a Containerized Ocean Thermal Energy Conversion Prototype
by
Jingyi Liu, Fuzhen Xing, Yawei Wang, Yizhou Li, Fenlan Ou, Qiongfeng Shi, Bo Ning and Guobiao Hu
Machines 2026, 14(10), 1112; https://doi.org/10.3390/machines14101112 - 28 Sep 2026
Abstract
Ocean Thermal Energy Conversion (OTEC) is a promising renewable energy technology for remote islands, offshore platforms, and maritime infrastructure, yet its commercialization is constrained by low cycle efficiency, high auxiliary energy demand, and the engineering challenges associated with large-scale seawater transport. This study
[...] Read more.
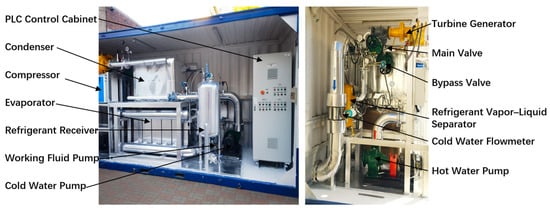
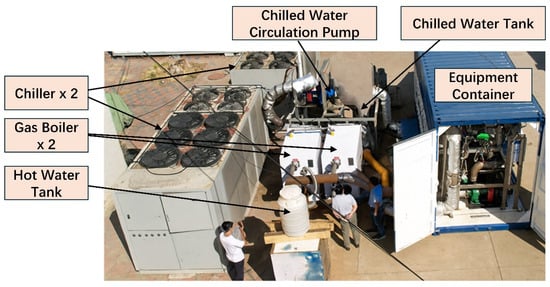
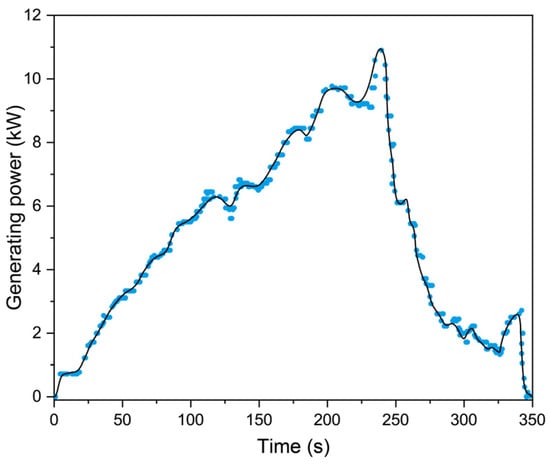
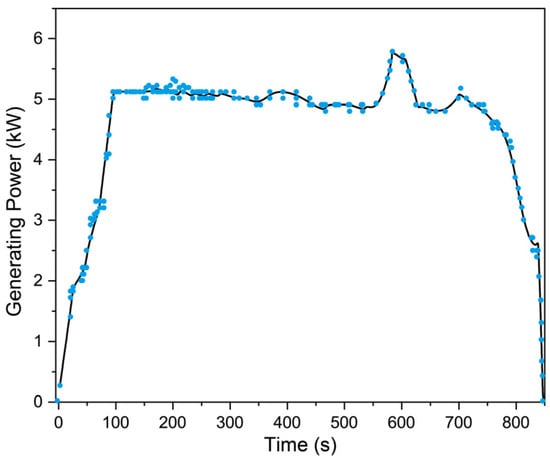
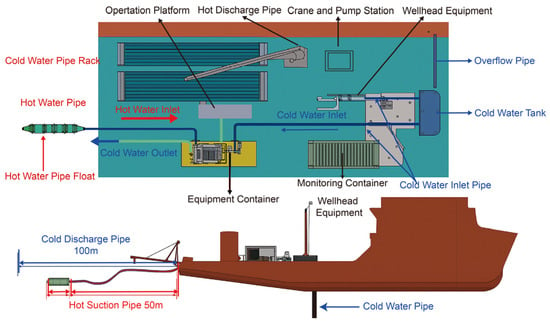
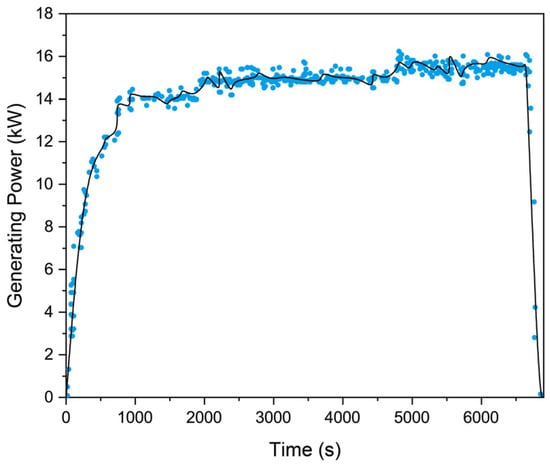
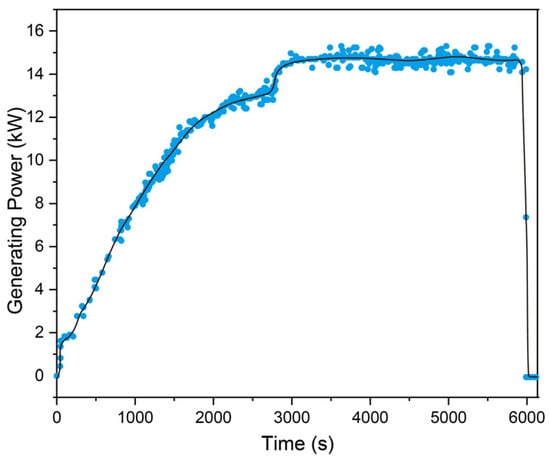
Ocean Thermal Energy Conversion (OTEC) is a promising renewable energy technology for remote islands, offshore platforms, and maritime infrastructure, yet its commercialization is constrained by low cycle efficiency, high auxiliary energy demand, and the engineering challenges associated with large-scale seawater transport. This study presents the integration and experimental evaluation of a 20 kW class containerized OTEC prototype using R134a in a closed Rankine cycle. The working fluid circulates within the power-generation module, while warm surface seawater supplies the evaporator and cold deep seawater is pumped through an insulated intake pipe to the container-mounted condenser. The prototype integrates a radial-inflow turbine, stainless-steel heat exchangers, circulation pumps, and a programmable logic controller-based control system. Land-based commissioning tests, conducted at initial warm-to-cold-water temperature differences of approximately 20–25 °C, produced a peak electrical output of 11 kW in one run and approximately 5 kW for 11 min in another. Sea trials in the South China Sea recorded a peak electrical output of 16.4 kW and a cumulative power-generation duration of 4 h 47 min across separate runs. These results document the integration and short-duration operation of the prototype under offshore conditions and identify priorities for improved control and longer-duration testing.
Full article
(This article belongs to the Section Electrical Machines and Drives)
►▼
Show Figures

Figure 1
Open AccessFeature PaperArticle
Design and Experimental Validation of a Sweet Potato Seedling Transplanting Mechanism Based on a Non-Circular Planetary Gear Train and Fourier Series Synthesis
by
Bingliang Ye, Jiacheng Sang, Xuefu Yu, Zhaoming Guan, Mengying Yan and Tao Tang
Machines 2026, 14(10), 1111; https://doi.org/10.3390/machines14101111 - 27 Sep 2026
Abstract
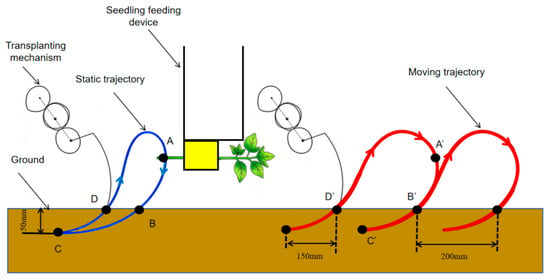
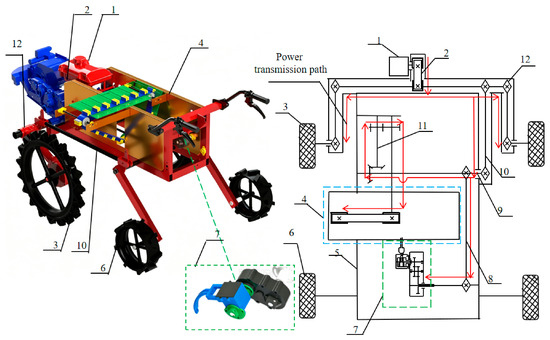
To address the high cost, structural complexity, and poor horizontal transplanting performance of existing sweet potato seedling transplanting mechanisms, this study proposes a Fourier series-based kinematic synthesis method and designs a non-circular gear planetary transplanting mechanism, which is then validated through virtual simulation
[...] Read more.
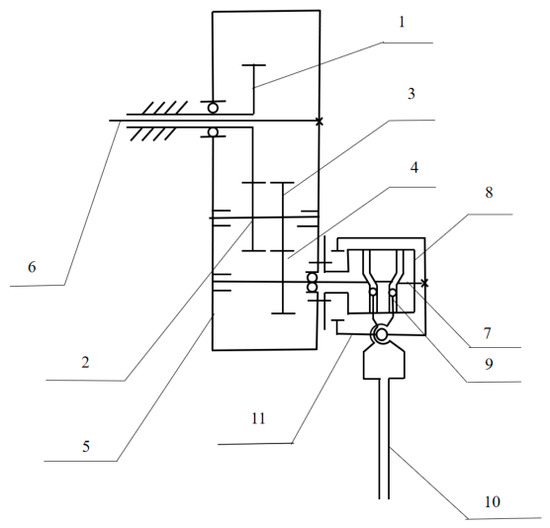
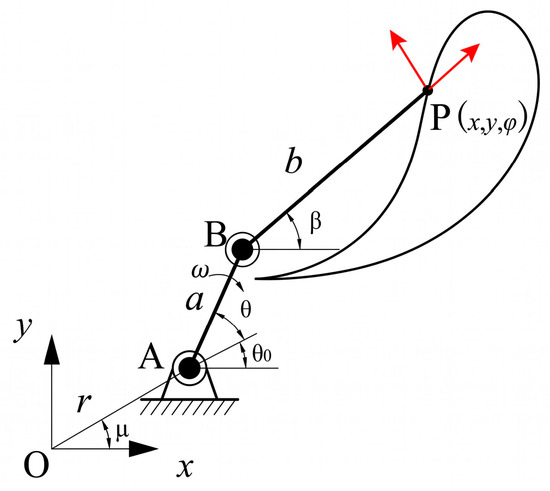
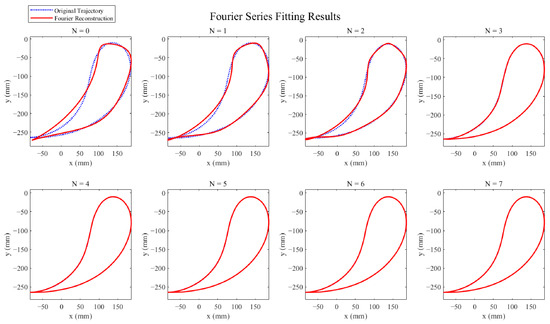
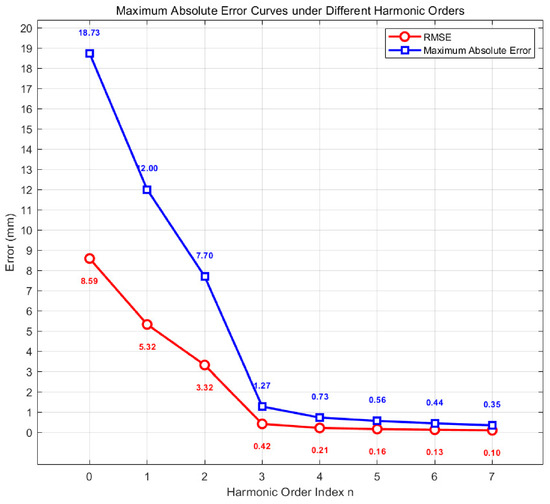
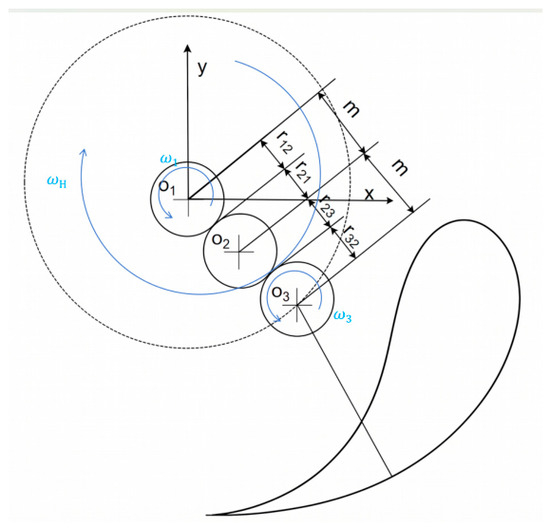
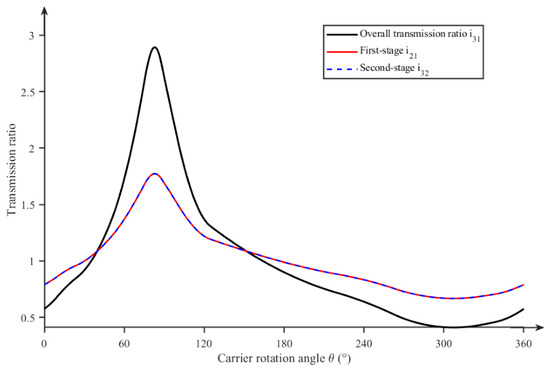
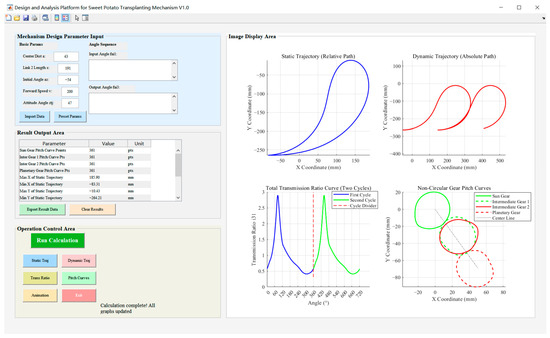
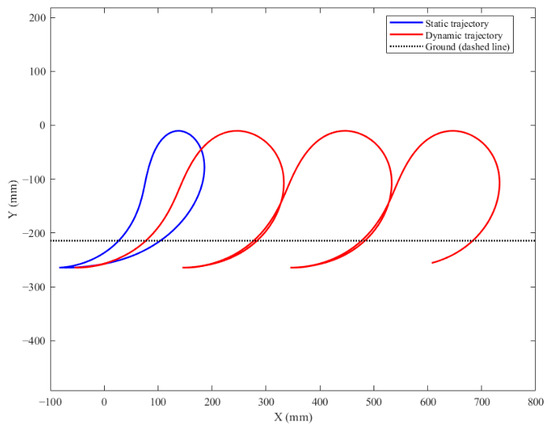
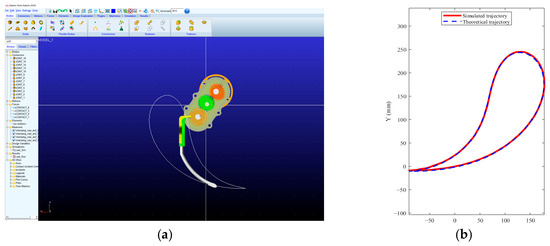
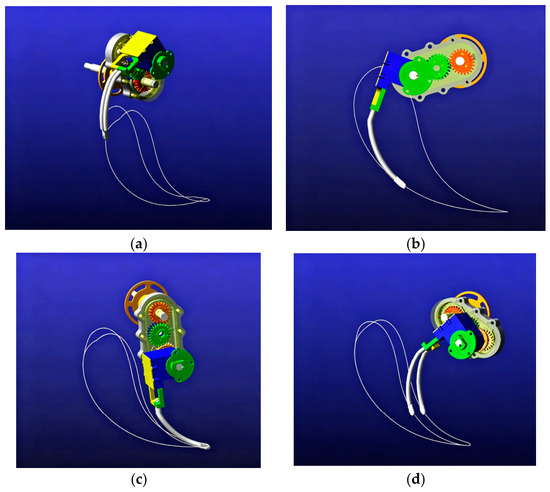
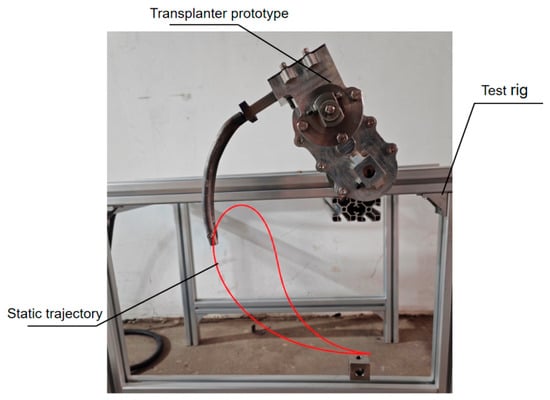
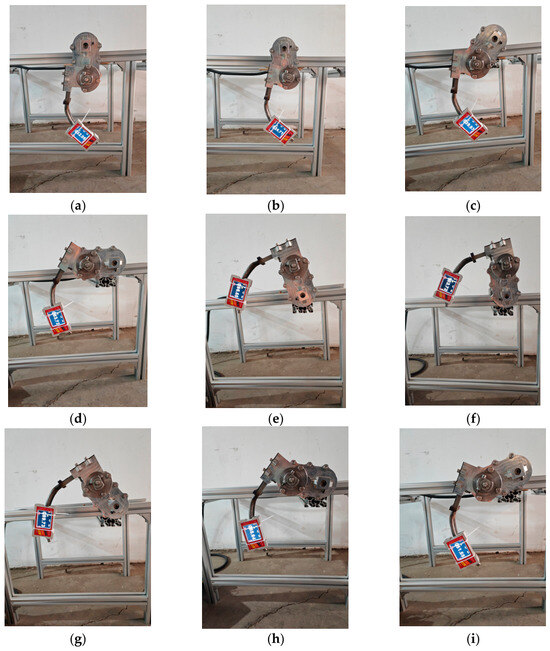
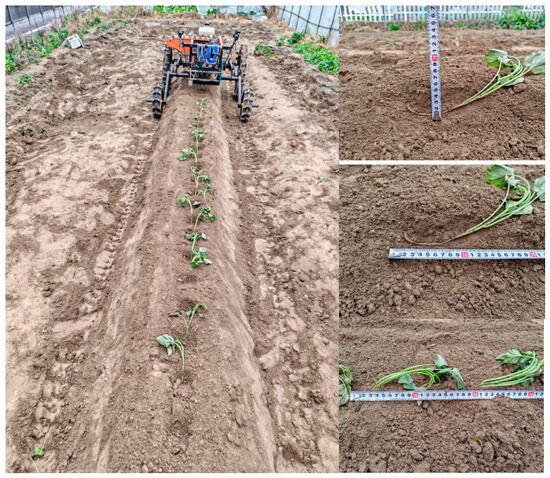
To address the high cost, structural complexity, and poor horizontal transplanting performance of existing sweet potato seedling transplanting mechanisms, this study proposes a Fourier series-based kinematic synthesis method and designs a non-circular gear planetary transplanting mechanism, which is then validated through virtual simulation and prototype testing. Based on the agronomic requirements for horizontal transplanting, key positions including seedling pick-up, soil entry, and soil exit are identified. The complex vector method is applied to establish a 2R open-chain kinematic synthesis model with trajectory and posture error equations, from which the optimal mechanism parameters are derived. Kinematic modeling of the non-circular gear planetary train is conducted, and auxiliary design software is developed to generate the pitch curves of the non-circular gears. A cylindrical cam mechanism is designed for seedling gripping and release. Structural design and virtual prototyping are completed, and simulations verify the theoretical model. A physical prototype is manufactured for kinematic and field testing. The results demonstrate high consistency among the measured, simulated, and theoretical trajectories, with a maximum deviation of 0.6° (relative error of 0.83%) at the key posture positions. At rotational speeds of the transplanting mechanism of 30 r/min and 40 r/min, the average transplanting success rates reach 91.2% and 81.2%, respectively, while the planting depth, horizontal underground length, and plant spacing all satisfy the agronomic requirements, confirming the feasibility of the proposed design. This study provides a theoretical and technical foundation for the development of a high-performance sweet potato seedling transplanting mechanism.
Full article
(This article belongs to the Section Machine Design and Theory)
►▼
Show Figures

Figure 1
Open AccessArticle
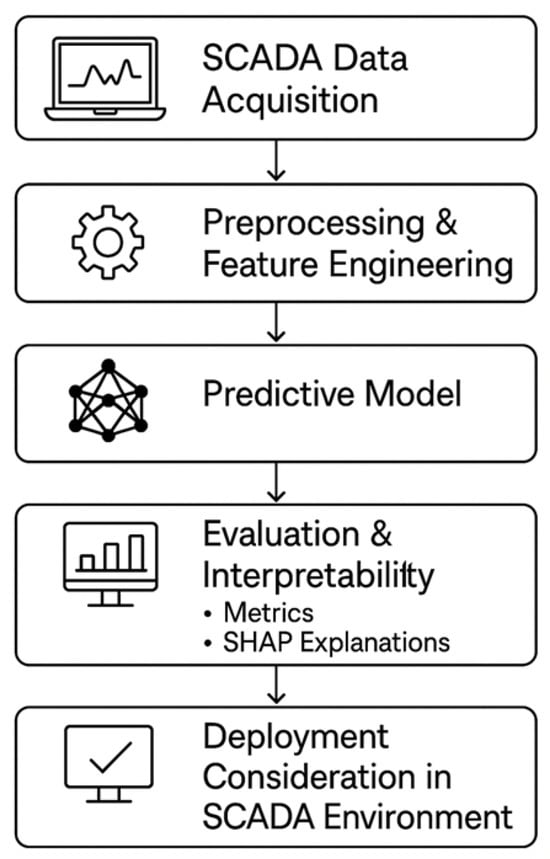
A Hierarchical GRU-Based Predictive Maintenance Framework for SCADA-Monitored Water Pump Stations
by
Lorraine Ramaphala, Pitshou N. Bokoro and Wesley Doorsamy
Machines 2026, 14(10), 1110; https://doi.org/10.3390/machines14101110 - 27 Sep 2026
Abstract
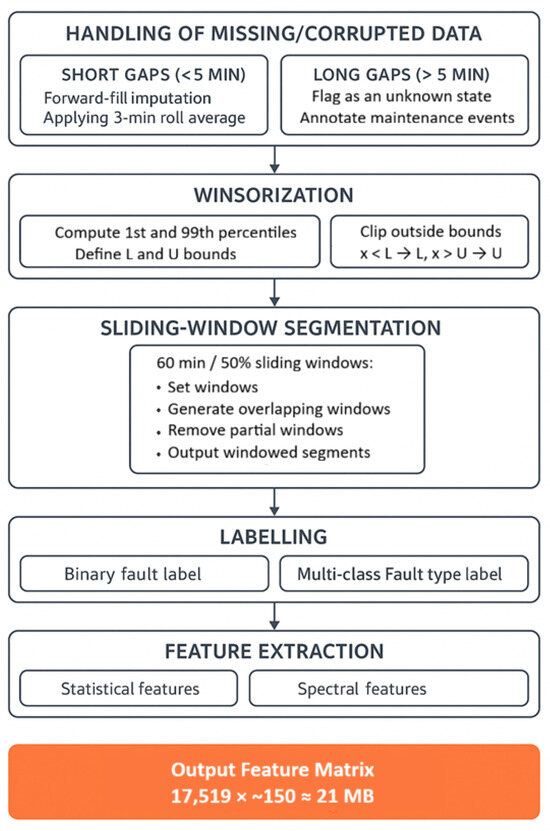
This study investigates predictive maintenance for SCADA-controlled pump stations using multi-sensor data processing and hybrid machine-learning models. The conventional maintenance approaches adopted in practice remain reactive, with little provision for actual early warnings under real-world conditions such as noisy data, class imbalance, or
[...] Read more.
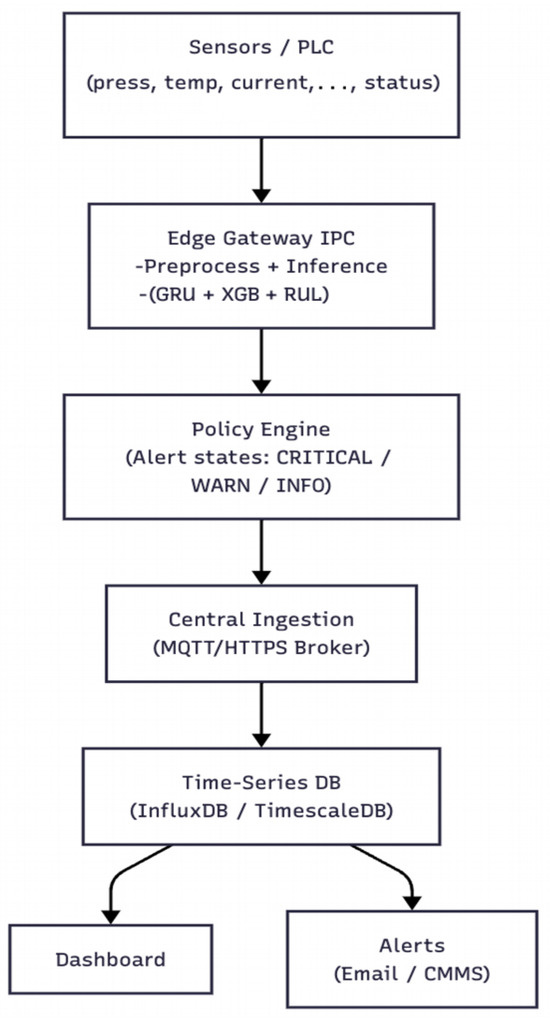
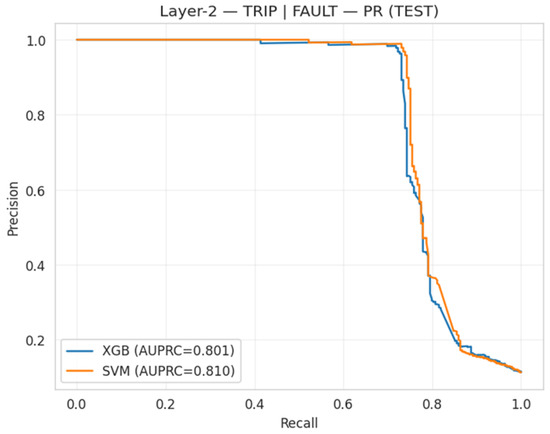
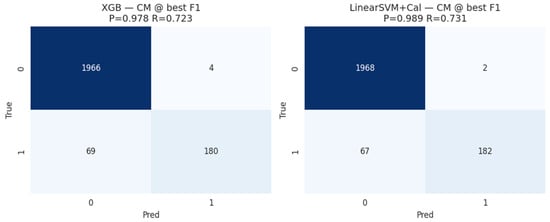
This study investigates predictive maintenance for SCADA-controlled pump stations using multi-sensor data processing and hybrid machine-learning models. The conventional maintenance approaches adopted in practice remain reactive, with little provision for actual early warnings under real-world conditions such as noisy data, class imbalance, or varying sensor dynamics. A data-driven solution is proposed to predict pump tripping events using operational SCADA system data for early warning with useful lead times. The dataset, obtained from a water-utility SCADA system, contained missing values, heavy-tailed sensor distributions, and substantial class imbalance. The preprocessing strategy used time-aware imputation, winsorisation, and a sliding-window configuration informed by the characteristics of the SCADA data. Benchmark machine-learning models achieved PR-AUC values of approximately 0.55 or lower for trip-escalation prediction, highlighting the difficulty of predicting rare trip events directly from SCADA data. The proposed hierarchical GRU-based framework achieved PR-AUC values exceeding 0.80, demonstrating a substantial improvement in predictive performance while maintaining high precision and low false-alarm rates. In addition, a Remaining Useful Life (RUL) component was included to extend the system to support near-term risk forecasting. Even so, long-term forecasts remained uncertain, indicating that further model development is required.
Full article
(This article belongs to the Section Machines Testing and Maintenance)
►▼
Show Figures

Figure 1
Open AccessEditorial
Advanced Manufacturing Processes and Technologies: Trends and Innovations
by
Panagiotis Kyratsis and Pierre Vella
Machines 2026, 14(10), 1109; https://doi.org/10.3390/machines14101109 - 27 Sep 2026
Abstract
Advanced manufacturing processes and technologies have transformed various industries by enabling more efficient, sustainable, and precise production methods [...]
Full article
(This article belongs to the Special Issue Advanced Manufacturing Processes and Technologies: Trends and Innovations)
Open AccessArticle
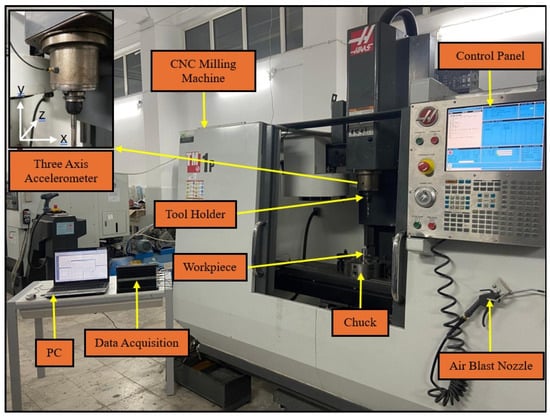
Multi-Axis Acceleration Response Prediction in Milling: An Artificial Intelligence-Based Approach
by
Muhammed İşci
Machines 2026, 14(10), 1108; https://doi.org/10.3390/machines14101108 - 27 Sep 2026
Abstract
►▼
Show Figures
Vibrations generated during cutting in machining processes present a significant challenge, directly impacting surface quality, tool longevity, and processing efficiency. Accurate modeling of vibration behavior under varying cutting conditions is therefore essential for advancing the understanding of machining dynamics. In this research, triaxial
[...] Read more.
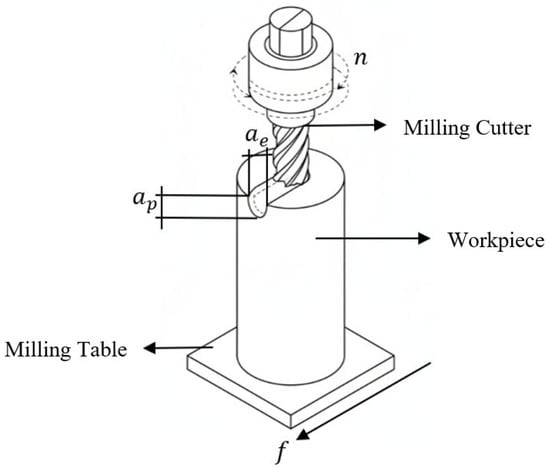
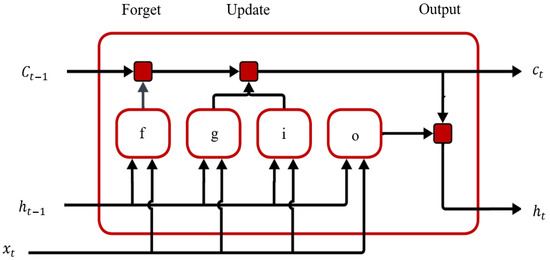
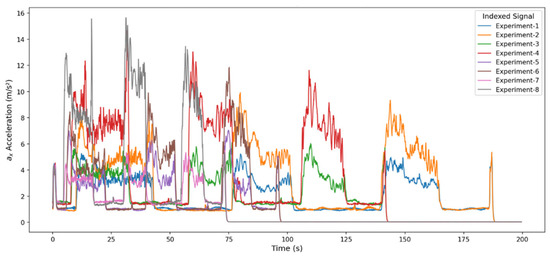
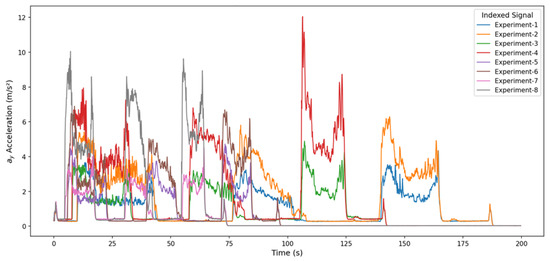
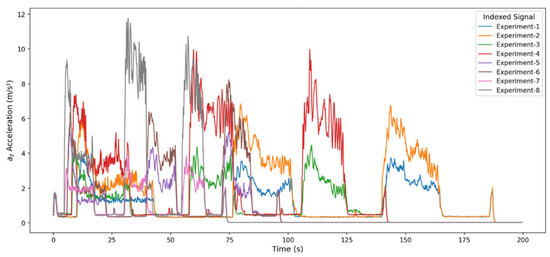
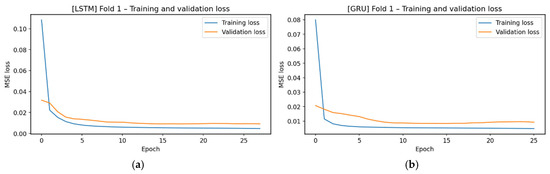
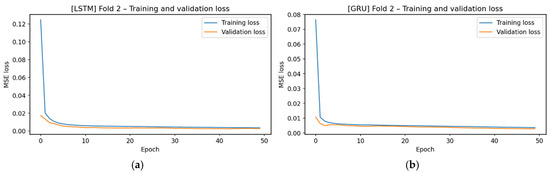
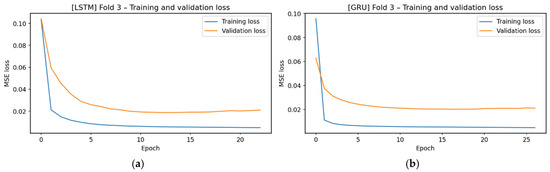
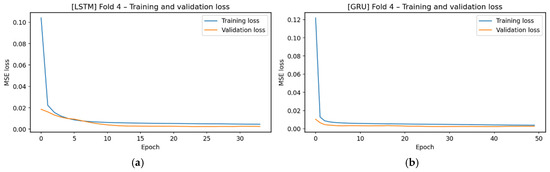
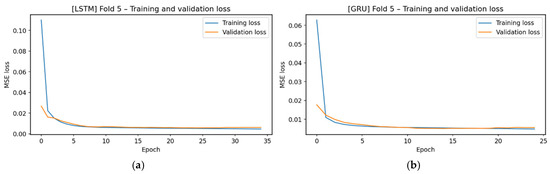
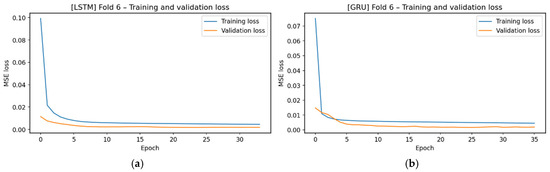
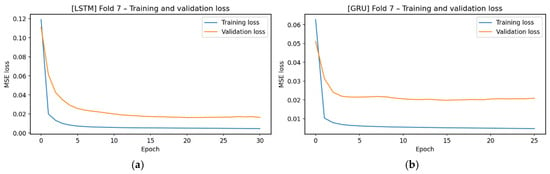
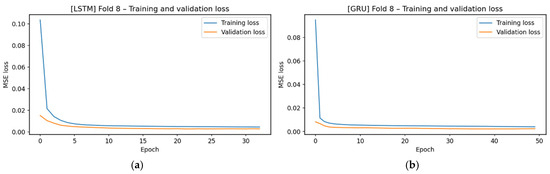
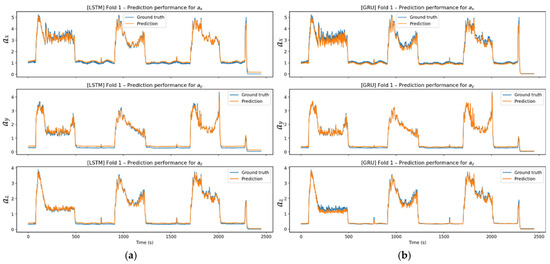
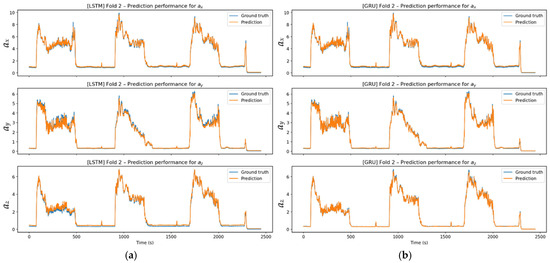
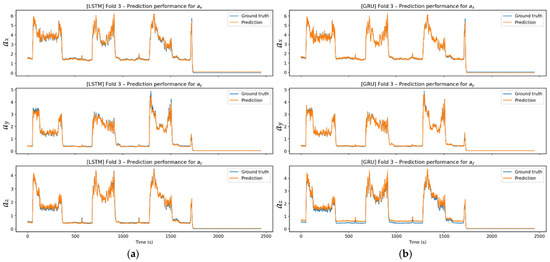
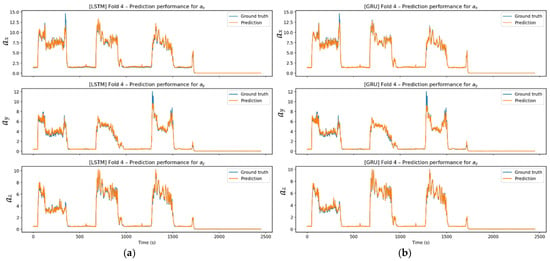
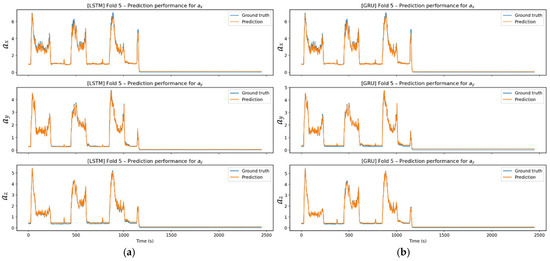
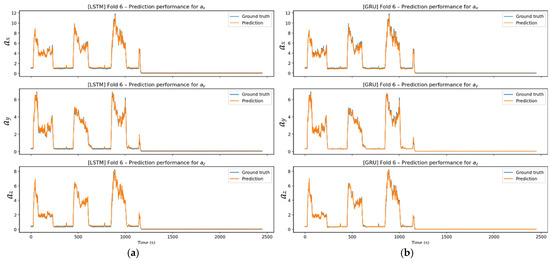
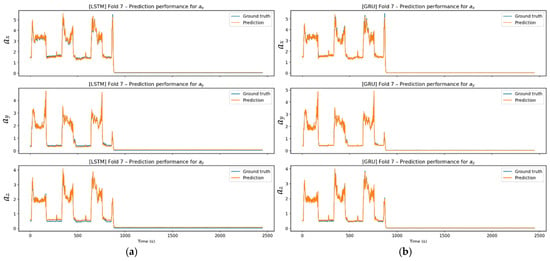
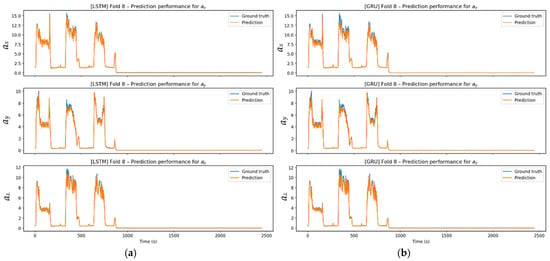
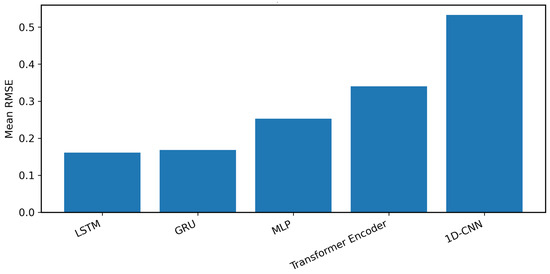
Vibrations generated during cutting in machining processes present a significant challenge, directly impacting surface quality, tool longevity, and processing efficiency. Accurate modeling of vibration behavior under varying cutting conditions is therefore essential for advancing the understanding of machining dynamics. In this research, triaxial vibration accelerations in the tool holder region during CNC milling of Al 6061 material were experimentally measured. The proposed framework focuses on the prediction of process-level time-domain acceleration responses rather than high-frequency chatter or tooth-passing vibration components. The experiments incorporated a range of spindle speeds, feed rates, and depths of cut. The resulting multi-axial acceleration time series were modeled using deep learning-based time series approaches to capture complex and nonlinear dynamics. Specifically, Long Short-Term Memory (LSTM) and Gated Recurrent Unit (GRU) architectures were developed, and their generalization capabilities were assessed using the Leave-One-Experiment-Out (LOEO) method. Comparative analyses employing root mean square error (RMSE), mean absolute error (MAE), and coefficient of determination (R2) metrics indicate that both models reliably predict multi-axis acceleration responses. Notably, the LSTM architecture demonstrates a more balanced learning performance for representing long-term dynamics. These findings provide an effective, practical approach to data-driven modeling of vibrations in CNC milling processes.
Full article

Figure 1
Open AccessArticle
Collaborative Scheduling Optimization of Staging and Transfer Operations for Mixed Unmanned Aerial Vehicle Fleets at Offshore Wind Power Substations
by
Wei Han, Xiangyu Liu, Xichao Su, Bing Wan, Fang Guo and Changjiu Li
Machines 2026, 14(10), 1107; https://doi.org/10.3390/machines14101107 - 26 Sep 2026
Abstract
Offshore wind power substations serve as fixed bases for unmanned aerial vehicle logistics distribution. In the mixed-fleet scheduling of multiple unmanned aerial vehicle types, parking spot allocation, configuration decisions, and transfer timing are deeply coupled, rendering traditional scheduling algorithms ineffective for efficient solution.
[...] Read more.
Offshore wind power substations serve as fixed bases for unmanned aerial vehicle logistics distribution. In the mixed-fleet scheduling of multiple unmanned aerial vehicle types, parking spot allocation, configuration decisions, and transfer timing are deeply coupled, rendering traditional scheduling algorithms ineffective for efficient solution. To address this, this paper takes the context of substations performing material delivery and inspection missions to surrounding wind turbines, maintenance vessels, and other offshore facilities. An optimization model is constructed that comprehensively considers group priority, aircraft type differentiation, and configuration transition factors, with objectives of minimizing total transfer time, number of configuration changes, and workload variance among transfer crews. An event-driven configurable greedy initial solution generation strategy is introduced, and an adaptive large neighborhood search algorithm is designed, incorporating domain-knowledge-driven destruction and repair operators, an adaptive weight mechanism, and a simulated annealing acceptance criterion. Experimental results demonstrate that the proposed algorithm achieves the optimal mean objective values across all six test cases, outperforming the conventional adaptive large neighborhood search algorithm by 7.0–7.9% and the genetic algorithm by 14.4–22.1%, while maintaining the lowest standard deviation. The algorithm exhibits robust stability and practical applicability, providing effective decision support for unmanned aerial vehicle logistics distribution scheduling at offshore wind power substations.
Full article
(This article belongs to the Special Issue Optimization-Based Motion Planning & Control for Autonomous Driving in Dynamic Environments)
Open AccessArticle
Learning Scheduling Method for Mixed Traffic at Autonomous Intersections Without Reliable Explicit Turn Information of Human-Driven Vehicles
by
Xuhao Yue, Feng Peng, Zejian Deng, Haoran Li, Chuan Sun, Hao Shi and Haiming Sun
Machines 2026, 14(10), 1106; https://doi.org/10.3390/machines14101106 - 26 Sep 2026
Abstract
At autonomous intersections in mixed traffic, where Connected and Autonomous Vehicles (CAVs) coexist with Human-Driven Vehicles (HDVs), scheduling must remain effective even when a reliable explicit HDV turning intention is not available sufficiently early for the scheduling decision. This paper proposes a learning-based
[...] Read more.
At autonomous intersections in mixed traffic, where Connected and Autonomous Vehicles (CAVs) coexist with Human-Driven Vehicles (HDVs), scheduling must remain effective even when a reliable explicit HDV turning intention is not available sufficiently early for the scheduling decision. This paper proposes a learning-based platoon scheduling method for this information-limited setting. CAVs and HDVs are organized into mixed platoons or an HDV group, and a state-augmentation function is designed to encode their temporal relationship while preserving the priority of uncontrollable HDVs. An enumeration (EN)-based expert demonstration mechanism is further integrated into the training process to provide high-quality experience. In the representative training run reported in the manuscript, the expert-assisted model achieved a peak average reward approximately 14% higher than the model trained without demonstrations. Across the tested demand cases, the learned scheduler also obtained travel-cost performance close to the EN benchmark. The scope of the method is explicitly limited to the modeled lane-keeping and sensing assumptions; robustness to random seeds, unexpected HDV maneuvers, communication delays, and additional safety metrics requires dedicated validation.
Full article
(This article belongs to the Special Issue Control and Path Planning for Autonomous Vehicles)
Open AccessArticle
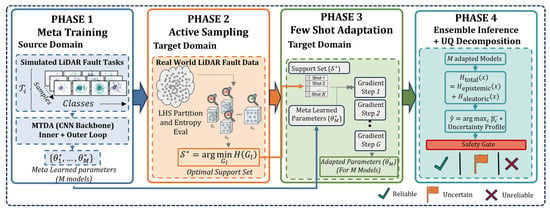
Uncertainty-Decomposed Meta-Learning with Reliability-Gated Inference for Intelligent Few-Shot LiDAR Fault Classification
by
Mainak Mallick, Seong-Geun Shin, Hyuck-kee Lee and Seung-Kyum Choi
Machines 2026, 14(10), 1105; https://doi.org/10.3390/machines14101105 - 26 Sep 2026
Abstract
Few-shot meta-learning supports rapid adaptation with limited labeled data, but remains sensitive to hyperparameters and support set quality. We propose Uncertainty-Decomposed Reliability-Gated Meta-Learning (UDRML). It selects support sets with low predictive entropy, combines diverse adapted models to estimate aleatoric and epistemic uncertainty through
[...] Read more.
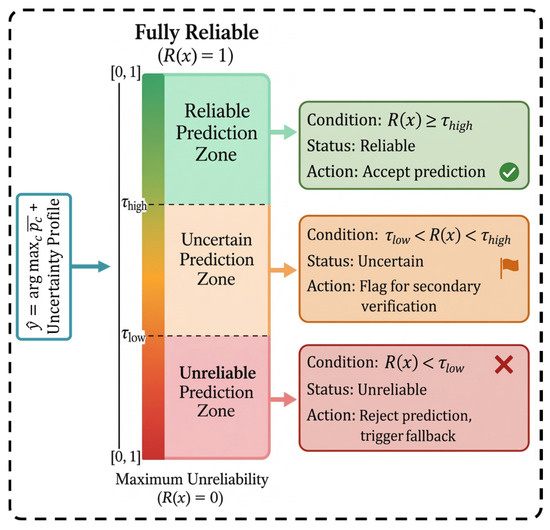
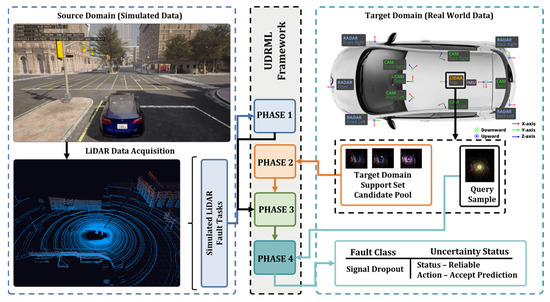
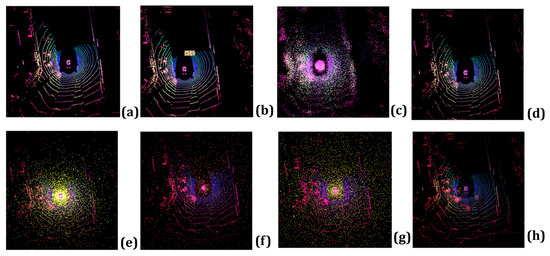
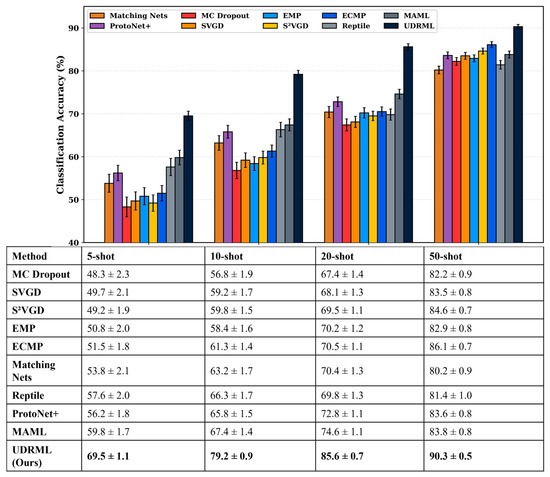
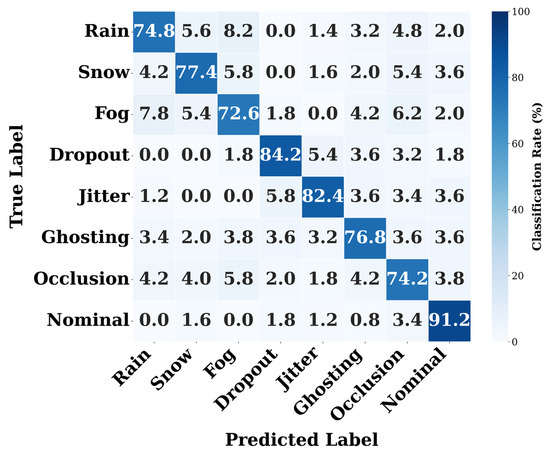
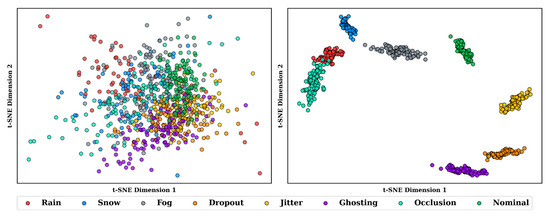
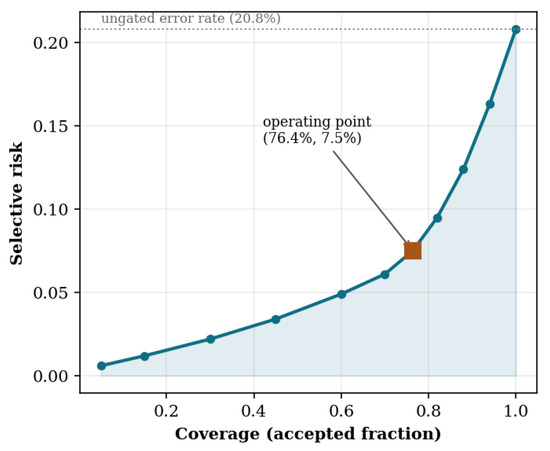
Few-shot meta-learning supports rapid adaptation with limited labeled data, but remains sensitive to hyperparameters and support set quality. We propose Uncertainty-Decomposed Reliability-Gated Meta-Learning (UDRML). It selects support sets with low predictive entropy, combines diverse adapted models to estimate aleatoric and epistemic uncertainty through mutual information, and uses a reliability score to accept, flag, or reject predictions. We evaluate UDRML on cross-domain few-shot LiDAR fault classification using a synthetically augmented nuScenes dataset. At 10-shot, UDRML improves accuracy over MAML by 11.8 points. Gating provides a further 13.3-point gain on accepted predictions, while measured epistemic uncertainty is 78% lower than that of the strongest ensemble baseline, ECMP. The framework supports selective automation by accepting reliable predictions and directing uncertain cases to verification or a fallback.
Full article
(This article belongs to the Special Issue Digital Twins and Intelligent Systems for Condition-Based Industrial Maintenance)
►▼
Show Figures

Figure 1
Open AccessArticle
Multimode Input Shaping for Quay-Side Container Cranes with Multibody-Based Frequency Correction
by
Gerardo Peláez, Pablo Izquierdo, Gustavo Peláez and Higinio Rubio
Machines 2026, 14(10), 1104; https://doi.org/10.3390/machines14101104 - 26 Sep 2026
Abstract
This work investigates multimode vibration suppression in quay-side container cranes by combining analytical modeling, nonlinear multibody simulation, robust Input Shaping, and experimental implementation. A linearized double-pendulum model preserving the main geometric and inertial properties of the spreader–ISO-container assembly is first derived to characterize
[...] Read more.
This work investigates multimode vibration suppression in quay-side container cranes by combining analytical modeling, nonlinear multibody simulation, robust Input Shaping, and experimental implementation. A linearized double-pendulum model preserving the main geometric and inertial properties of the spreader–ISO-container assembly is first derived to characterize its coupled dynamics, comprising a low-frequency global pendular mode and a higher-frequency relative ringing mode. The errors introduced by linearization are assessed against a higher-fidelity Simscape Multibody model over a wide range of operating configurations. The comparison shows that the analytical formulation provides sufficiently accurate estimates of the modal frequency ranges for robust shaper design. Two Unity Magnitude One-Hump shapers are therefore synthesized for the identified low- and high-frequency bands and subsequently convolved into a multimode bang–off–bang command. Sensitivity analysis confirms simultaneous attenuation of both target frequency ranges. Numerical validation on the nonlinear multibody model shows that the reduction in residual vibration remains above 90% over the investigated variations in hoisting length and ISO-container center-of-mass position. Finally, a PLC-based laboratory implementation demonstrates that Unity Magnitude shaping can be executed through timed command toggles without online convolution, supporting its practical implementation using conventional industrial control hardware.
Full article
(This article belongs to the Special Issue Passive and Active Approaches for the Control of Nonlinear Vibrations in Mechanical Systems)
Journal Menu
► ▼ Journal Menu-
- Machines Home
- Aims & Scope
- Editorial Board
- Reviewer Board
- Topical Advisory Panel
- Early Career Editorial Board
- Instructions for Authors
- Special Issues
- Topics
- Sections & Collections
- Article Processing Charge
- Indexing & Archiving
- Editor’s Choice Articles
- Most Cited & Viewed
- Journal Statistics
- Journal History
- Journal Awards
- Society Collaborations
- Conferences
- Editorial Office
Journal Browser
► ▼ Journal BrowserHighly Accessed Articles
Latest Books
E-Mail Alert
News
Topics
Topic in
Electronics, Fluids, Machines, Micromachines, Applied Sciences
Micro-Mechatronic Engineering, 2nd Edition
Topic Editors: Teng Zhou, Antonio F. MiguelDeadline: 31 October 2026
Topic in
Applied Sciences, Electronics, J. Imaging, JMSE, Machines, Robotics, Sensors, Drones
Applications and Development of Underwater Robotics and Underwater Vision Technology, 2nd Edition
Topic Editors: Jingchun Zhou, Wenqi Ren, Qiuping Jiang, Yan-Tsung PengDeadline: 30 November 2026
Topic in
Alloys, Metals, Machines, Applied Sciences
Welding Experiment and Simulation
Topic Editors: Yuewei Ai, Jiangwei LiuDeadline: 31 December 2026
Topic in
Actuators, Automation, Electronics, Machines, Robotics, Eng, Technologies
New Trends in Robotics: Automation and Autonomous Systems
Topic Editors: Maki Habib, Fusaomi NagataDeadline: 31 January 2027
Conferences
Special Issues
Special Issue in
Machines
Advanced Machine Condition Monitoring and Fault Diagnosis
Guest Editor: Gómez María JesúsDeadline: 30 September 2026
Special Issue in
Machines
Advanced Estimation, Control, and Optimization Techniques for Synchronous Machines in Next-Generation Electrified Systems
Guest Editors: Peter Azer, Ahmed AbdelrahmanDeadline: 30 September 2026
Special Issue in
Machines
Advanced Manufacturing Technologies for Improving Fatigue Behavior of Metal Components
Guest Editors: Galya Velikova Duncheva, Jordan Todorov MaximovDeadline: 30 September 2026
Special Issue in
Machines
Advanced Control Techniques for Power Electronics in Modern Energy Systems
Guest Editors: Moria Sassonker Elkayam, Dmitri VinnikovDeadline: 30 September 2026
Topical Collections
Topical Collection in
Machines
Machines, Mechanisms and Robots: Theory and Applications
Collection Editor: Raffaele Di Gregorio