Skip to Content
You are currently on the new version of our website. Access the old version .
  • 2.9
    Impact Factor
  • 4.5
    CiteScore
  • 25 days
    Submission to First Decision
  • 6 days
    Acceptance to Publication

Automation

Automation is an international, peer-reviewed, open access journal on automation and control systems published bimonthly online by MDPI.

Get Alerted

Add your email address to receive forthcoming issues of this journal.

All Articles (397)

  • Article
  • Open Access

Electric motors are the principal power units of industry, and their failures cause cascading stoppages of process equipment. The vibration signal carries the most complete information about the condition of rotating assemblies, yet machine-learning diagnostics is constrained by the shortage of labelled fault data. This work proposes and verifies a methodology for generating a physically grounded synthetic dataset of vibration signals: analytical models of imbalance, misalignment, rolling-bearing defects (BPFO, BPFI, BSF, FTF) and mechanical looseness produced 8000 one-second fragments of vibration acceleration covering eight classes of technical state, with variation of the rotational frequency (±5%), signal-to-noise ratio (5–30 dB) and defect amplitude. The synthetic signals were verified against reference Case Western Reserve University (CWRU) records: the outer- and inner-ring defect frequencies agree within 0.22%, and the envelope spectra are class-specific for these defects. Six classifiers were compared in three stages: Random Forest, XGBoost, a 1D-CNN (WDCNN), two 2D-CNNs on STFT and CWT representations, and a PatchTST transformer. Under the full set of variations, models reached a Macro F1 of 99.6–99.8%. On the real CWRU records, separate models were trained on the dataset based on real data from other operating loads. On the unseen loads, the Random Forest reached a Macro F1 of 95.5% and the 1D-CNN 93.2%, against 21–42% for the same models trained on synthetic data alone, and with one real fragment per class, the difference between the two training datasets was already 17–32 p.p. High accuracy on synthetic data therefore did not carry over to zero-shot diagnosis on the real bench.

Automation

16 November 2026

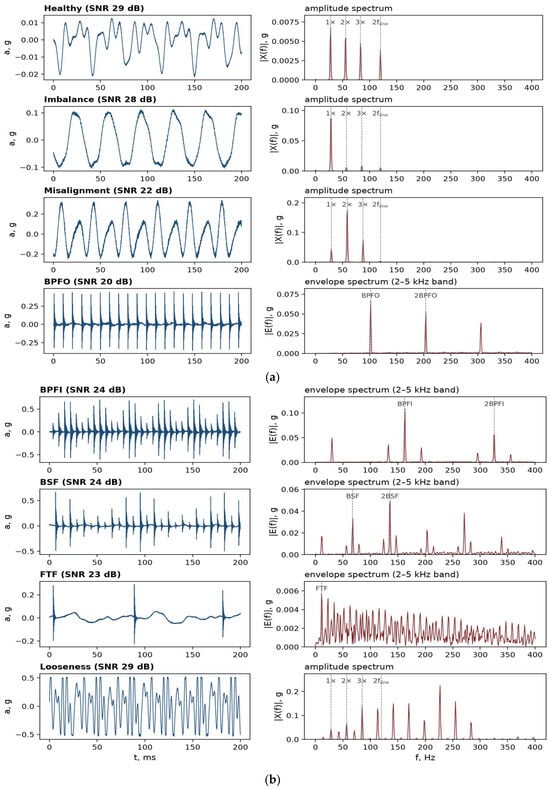
(a) Synthetic signals for Healthy, Imbalance, Misalignment and BPFO: first 200 ms (left) and amplitude or envelope spectra (right). The bearing envelope spectrum uses the 2–5 kHz band. The remaining classes are shown in part (b). (b) Synthetic signals for BPFI, BSF, FTF and Looseness: first 200 ms (left) and envelope spectra for bearing defects or amplitude spectrum for Looseness (right). Time is in milliseconds and frequency in hertz. The bearing envelope spectra use the 2–5 kHz band.
  • Article
  • Open Access

This paper proposes a novel elasto-geometrical coupling calibration and an adaptive parameter identification method for flexible redundant manipulators. For the modeling, an elasto-geometrical coupling calibration model containing kinematic parameter errors and non-kinematic errors is constructed. Secondly, an adaptive identification rule is formulated to suppress the elasto-geometrical modeling errors according to the residual linearization errors in each iteration, thus obtaining accurate identification results even in the case of highly elastic joints. Thirdly, a dual-target measuring strategy based on multi-source sensing is designed to obtain high-precision hand-eye data; thus, lightweight sensors and a vision system suitable for flexible light-load manipulators can be practically used for the calibration. As revealed by simulation tests, the newly developed identification algorithm can progressively compensate for considerable linearization modeling discrepancies for a redundant robotic arm with 12 highly elastic joints. All error parameters are estimated with an accuracy above 99% through iterative updates. Corresponding experiments are carried out on an eight-joint cable-driven elastic redundant manipulator, and the results indicate the new calibration method reaches the fastest algorithm convergence and residuals at the same level when compared with two traditional ones.

Automation

13 November 2026

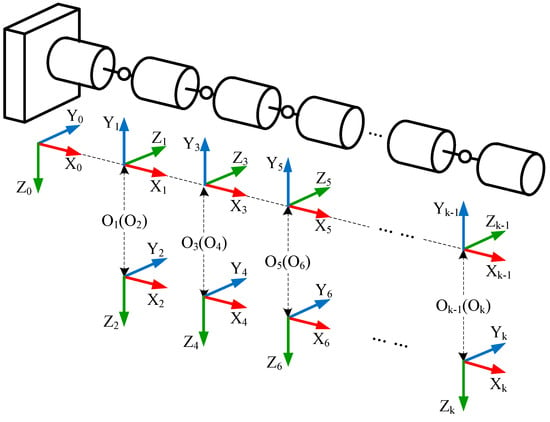
Coordinate frames of a hyper-redundant manipulator with k joints.
  • Article
  • Open Access

Wheel-actuator failure can compromise the trajectory-tracking capability of omnidirectional mobile robots, potentially interrupting material transport in automated warehouses. This study investigates control allocation reconfiguration to maintain trajectory tracking of a four-Mecanum-wheeled mobile robot after a single wheel actuator completely loses its torque-generation capability. Assuming that the failed actuator has already been detected and isolated, the proposed approach retains the nominal trajectory-tracking controller and redistributes the required generalized forces and yaw moment among the remaining actuators. The feasibility of post-fault tracking is examined through the rank of the available allocation matrix and the actuator torque limits. Five operating configurations are compared in simulation, including healthy operation, unreconfigured operation after failure, three-actuator reconfiguration, and two reduced two-actuator configurations. The achieved results demonstrate that, under the investigated simulation conditions, actuator-aware control allocation can preserve both position and orientation tracking after a single actuator failure without retuning the nominal controller, supporting continued robot motion during a post-fault operating interval.

Automation

12 November 2026

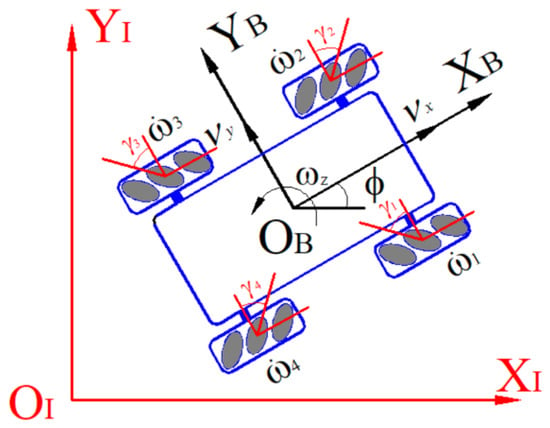
Kinematic configuration and coordinate frames of the four-Mecanum-wheeled mobile robot.
  • Article
  • Open Access

Sulfur recovery units (SRUs) at oil refineries are complex, multi-parameter systems whose Cold Bed Absorption (CBA) reactors operate under incomplete and uncertain process information, which limits conventional control. This study develops an engineering neuro-fuzzy decision support system (DSS) for optimizing sulfur production at the Atyrau oil refinery (Kazakhstan) under uncertainty. The system integrates a mathematical description of the process, whose dynamic part is stated as a general formulation, an expert-derived fuzzy rule base, a first-order Sugeno neuro-fuzzy estimator of sulfur yield and quality, and a multi-criteria fuzzy optimization block based on the Bellman–Zadeh approach, together with an explicit operator-facing decision algorithm and a software interface. The estimators were identified and validated on 200 operating log records of the unit. These records show that the effect of reactor temperature on the sulfur quality index reverses sign with reactor pressure—the correlation is −0.57 below 0.79 kgf/cm2 and +0.75 above it—so that a model additive in the two variables cannot represent the relationship: linear regression on temperature and pressure attains a cross-validated R2 of only 0.06 for the quality index, whereas the neuro-fuzzy estimator attains 0.83 (RMSE 0.72 points, MAPE 0.74%). A regression with an explicit interaction term on the same inputs attains 0.79; in a paired comparison the neuro-fuzzy estimator had the lower error in every repetition, but the difference is not statistically significant (p = 0.07), and the estimator is retained for its rule-level interpretability and its integration with the decision block. For sulfur yield, where the relationship is close to linear once pressure and throughput are accounted for, the corresponding figures are 0.71 and 0.85 (RMSE 0.33 t/day, MAPE 1.35%). The same ordering is reproduced on an independent hold-out test set, under nested and cluster-blocked cross-validation and after removal of the records lying at the unit’s capacity and regulatory bounds, and the expert rule base was revised into an asymmetric form accordingly. A worked application of the optimization block to three operating situations, with the production plan, quality and capacity constraints enforced, raised the model-predicted degree of joint satisfaction of the yield, quality and energy criteria from 0.08–0.25 to 0.49–0.57; in one of the three, the recommended action is to reduce process severity and lower a reheat duty surrogate by about a third rather than to increase output. The resulting DSS, at present a standalone advisory software prototype, supports the operator in analyzing the current process state, evaluating alternative operating modes and forming recommendations, while the final decision remains with the operator.

Automation

11 November 2026

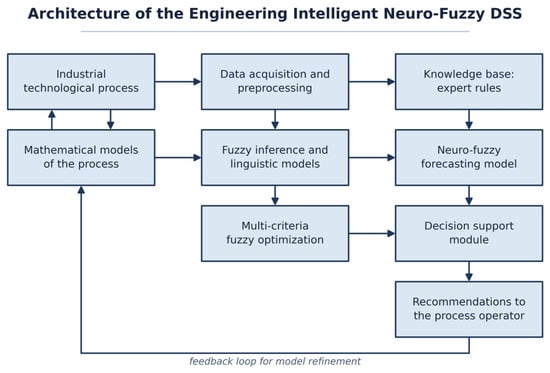
Engineering architecture of the intelligent neuro-fuzzy DSS for the sulfur production process; the lower return path denotes the feedback loop used for model refinement.

Highly Accessed Articles

News & Conferences

Latest Issues

Open for Submission

Journal Sections

XFacebookLinkedIn
Automation - ISSN 2673-4052