
 Open Access
- Article

20 Pages
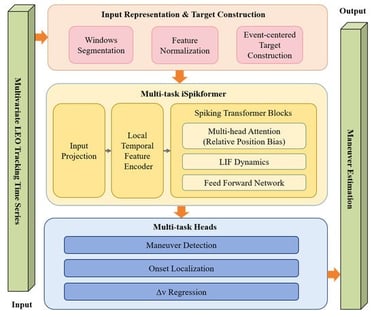
Low Earth orbit (LEO) maneuver analysis remains challenging because maneuver events are sparse and short in duration, while accurate analysis requires simultaneous maneuver detection, onset-time localization, and continuous three-dimensional velocity-increment (Δv) estimation from long multivariate tracking sequences. To address these challenges, an improved multi-task iSpikformer framework is proposed for the joint detection, onset-time localization, and three-dimensional velocity-increment estimation of low Earth orbit maneuvers from multivariate tracking time series. The model combines a local convolutional encoder, stacked spiking Transformer blocks, and task-specific output heads within a unified multi-task framework. Event-centered supervision, hard-negative optimization, and robust Δv regression are employed to improve sparse maneuver detection and continuous parameter estimation. For full-scene inference, predictions from overlapping windows are fused and converted into discrete maneuver events through boundary-aware event extraction and validation-based calibration. Unlike approaches that separately handle maneuver detection and parameter estimation or rely on conventional dense sequence modeling, the proposed framework jointly learns maneuver occurrence, onset location, and three-dimensional Δv from a shared temporal representation. Evaluation on a synthetic dataset of Starlink-like LEO trajectories showed that the proposed method achieved an F1-score of 0.9018, an onset-time MAE of 14.54 s, a component-wise Δv MAE of 0.0307 m/s, and a vector RMSE of 0.1302 m/s. Compared with representative baseline methods, the proposed method showed improved maneuver-detection performance and more accurate Δv estimation while maintaining comparable onset-localization accuracy. The inference-stride analysis further showed that inference time could be substantially reduced over a moderate stride range with limited changes in detection and estimation performance, whereas an excessively large stride reduced detection sensitivity. The proposed framework therefore provides a unified data-driven approach to event-level LEO maneuver analysis and demonstrates the applicability of spiking temporal modeling to joint maneuver detection and continuous orbital-parameter estimation.
Sensors
9 October 2026