Skip to Content
  • 2.2
    Impact Factor
  • 5.2
    CiteScore
  • 17 days
    Submission to First Decision
  • 3 days
    Acceptance to Publication

Symmetry

Symmetry is an international, peer-reviewed, open access journal covering research on symmetry/asymmetry phenomena wherever they occur in all aspects of natural sciences, and is published monthly online by MDPI.  

Get Alerted

Add your email address to receive forthcoming issues of this journal.

All Articles (18,236)

  • Article
  • Open Access

Heavy-duty cutter-changing manipulators in shield tunneling operate under abrupt payload attachment and release, extraction impacts, load-dependent friction, model uncertainty, actuator saturation, and measurement noise. These coupled effects can produce large transient tracking errors and excessive actuator demand. This paper develops a fractional-order memory-enhanced fixed-time symmetry-constrained tracking method. Payload-induced inertia variation, gravity mismatch, nonlinear friction, impacts, and unmodeled dynamics are aggregated into a heavy-load lumped disturbance. An acceleration-free momentum residual is combined with a Caputo fractional-order disturbance observer. For each joint, the tracking error is restricted to a zero-centered time-varying symmetric set, and an odd invertible transformation maps the constrained error into an unconstrained coordinate. A fixed-time terminal residual is then constructed in the transformed coordinates. Instead of placing a fractional integral directly in the sliding manifold, the proposed method introduces a nonnegative fractional memory term into the robust reaching gain, which preserves a standard fixed-time Lyapunov certificate while retaining historical residual information. A load-aware gain schedule is generated from the estimated disturbance magnitude. The fractional observer satisfies a componentwise Mittag–Leffler practical-error bound for bounded Caputo derivatives of the filtered input. The ideal sign-based reaching and terminal dynamics admit fixed-time bounds provided that the combined estimation and saturation residual remains below an explicit robustness margin; the smooth finite-memory implementation is evaluated numerically. Numerical studies on a two-link heavy-duty manipulator compare four controllers and examine ablations, fractional-order sensitivity, payload jumps, impacts, saturation and noisy model mismatch. Randomized paired trials quantify the loss of constraint feasibility under uncertain loading and saturation; computational-cost measurements characterize the offline implementation.

Symmetry

16 October 2026
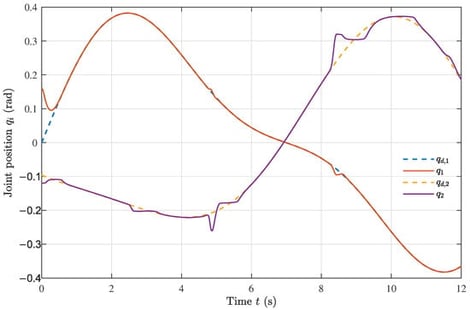
Joint tracking under the combined extreme-duty cycle.
  • Article
  • Open Access

The Drinfeld–Sokolov–Wilson (DSW) system originates in the theory of affine Lie algebras and the Korteweg–de Vries hierarchy, so that its integrability reflects an underlying algebraic symmetry that persists in rescaled form under fractionalization, and it also models dispersive shallow-water waves. This work applies the hybrid Aboodh–Temimi–Ansari technique to the time-fractional DSW system under the Caputo derivative, a scheme that requires neither Adomian nor He polynomials. We show that its iterates are exactly the Picard iterates of an equivalent fractional Volterra integral equation. Under a Lipschitz condition on the nonlinear operator, this yields the existence and uniqueness of a local solution by a Banach fixed-point argument, together with explicit bounds on the truncation error. We also show that the dispersive term of the DSW system prevents this condition from holding in the classical spaces of bounded smooth functions, so that the well-posedness of the fractional system itself remains open. Two initial value problems built from known kink and soliton profiles are solved, recovering the exact classical solution when the fractional order equals one. After two corrections, the approximations agree with the exact profiles to several significant figures, with the residual error concentrated where the nonlinear coupling is largest.

Symmetry

16 October 2026

  • Article
  • Open Access

Autonomous underwater vehicles (AUVs) have been extensively employed in diverse marine applications, where depth-tracking control remains a critical technical challenge. Although previous studies have investigated various guidance law designs for underactuated AUVs, compensation for the attack-angle effect induced by heave velocity remains underexplored, particularly in the presence of extreme time-varying external disturbances and sharp path curvature variations. Existing line-of-sight (LOS) based methods, including integral LOS (ILOS) and adaptive LOS (ALOS), rely solely on the integral action of the pitch-tracking error to estimate the attack angle, which inevitably introduces inherent time-delay characteristics and induces overshoot and chattering in the depth-tracking response. Given that a system’s position and its velocity are uniquely determined by its acceleration, a response-tunable adaptive LOS (RTALOS) guidance design is proposed for AUV depth-tracking control task. This guidance law incorporates both the depth-tracking error and its velocity term as boundary constraints, generating an acceleration reference through a time-based planning polynomial to achieve accurate attack-angle estimation. The proposed method redefines attack-angle estimation as a new paradigm based on a second-order depth-tracking kinematic system, where the introduced velocity term acts as an adjustable damping effect to effectively suppress the depth-tracking overshoot and oscillation. Simulations were conducted to verify that the proposed guidance design could make the depth-tracking motion converge within a given time duration if the state-constrained acceleration was promptly executed. Compared to the selected ILOS and ALOS methods, the proposed RTALOS method can rapidly and accurately compensate for time-varying attack-angle effects via the estimation of attack angle, resulting in precise depth-tracking control performance, even under severe time-varying disturbances and when the pitch-tracking control performance is unsatisfactory.

Symmetry

16 October 2026

  • Article
  • Open Access

This paper investigates the explicit solvability of the congruence equation . By exploiting properties of repdigit Niven numbers, we introduce several infinite families of primes with the square-free property and memory, thereby providing infinitely many explicit solutions to the congruence. Furthermore, we construct infinitely many new explicit Niven numbers. The results can be extended to the most general congruence equations for arbitrary coprime integers a and b. The results reveal a recursive structure linking the equation to prime factorizations of repunits, and we propose several conjectures concerning the square-free property of the arising prime sets. Beyond pure number-theoretic value, the derived hierarchical prime families and modular periodic structures may have broad potential physical application including discrete quantum circuit design, quasi-crystal diffraction spectrum modeling, periodic photonic grating engineering and so on.

Symmetry

16 October 2026

Highly Accessed Articles

News & Conferences

Latest Issues

Open for Submission

Journal Sections

Applications of Machine Learning in Large-Scale Optimization and High-Dimensional Learning
Reprint

Applications of Machine Learning in Large-Scale Optimization and High-Dimensional Learning

Editors: Jeng-Shyang Pan, Junzo Watada, Vaclav Snasel, Pei Hu
Intelligent Optimization Algorithm
Reprint

Intelligent Optimization Algorithm

Theory and Applications
Editors: Shi Cheng, Chaomin Luo, Shangce Gao
XFacebookLinkedIn
Symmetry - ISSN 2073-8994