Journal Description
Machines
Machines
is an international, peer-reviewed, open access journal on machinery and engineering, published monthly online by MDPI. The International Federation for the Promotion of Mechanism and Machine Science (IFToMM) is affiliated with Machines and its members receive a discount on the article processing charges.
- Open Access— free for readers, with article processing charges (APC) paid by authors or their institutions.
- High Visibility: indexed within Scopus, SCIE (Web of Science), Inspec, and other databases.
- Journal Rank: JCR - Q2 (Engineering, Mechanical) / CiteScore - Q1 (Control and Optimization)
- Rapid Publication: manuscripts are peer-reviewed and a first decision is provided to authors approximately 15.9 days after submission; acceptance to publication is undertaken in 2.9 days (median values for papers published in this journal in the first half of 2026).
- Recognition of Reviewers: Reviewers whose reports are timely and of high quality receive an APC discount voucher for a future publication in an MDPI journal. Become a reviewer.
- Journal Cluster of Mechanical Manufacturing and Automation Control: Aerospace, Automation, Drones, Journal of Manufacturing and Materials Processing, Machines, Robotics and Technologies.
- Companion journals for Machines include: Industries and Precision.
Impact Factor:
3.0 (2025);
5-Year Impact Factor:
2.9 (2025)
Latest Articles
Enhancing Sim-to-Real Transfer for a High-Gear-Ratio Quadruped Robot via Extended Actuator Dynamics Identification
Machines 2026, 14(9), 1031; https://doi.org/10.3390/machines14091031 - 9 Sep 2026
Abstract
Reinforcement learning (RL) has become a powerful tool for quadrupedal locomotion, and a sim-to-real approach is widely adopted to avoid hardware damage during training. However, the “sim-to-real gap” remains a critical challenge, particularly for robots driven by high-gear-ratio actuators, in which nonlinear friction
[...] Read more.
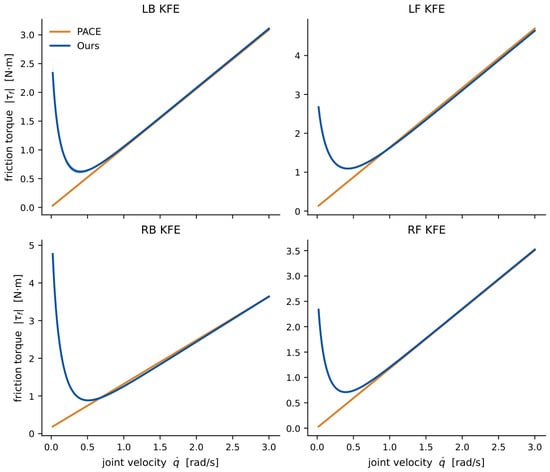
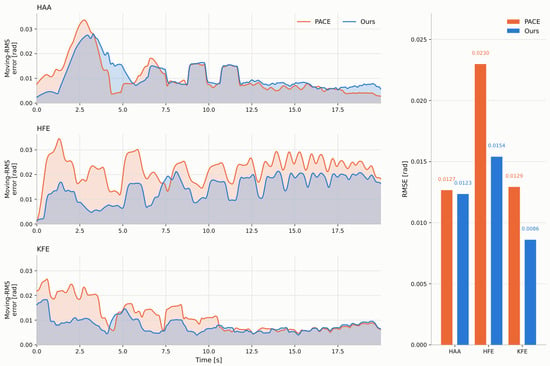
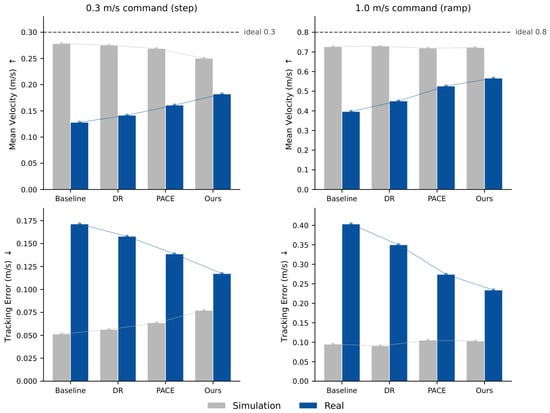
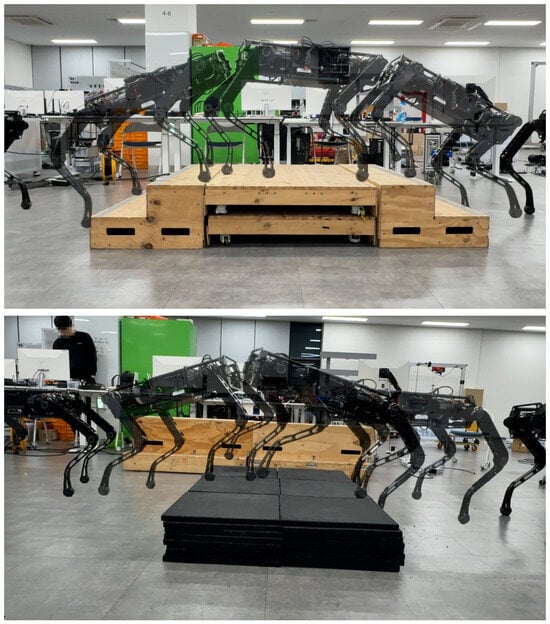
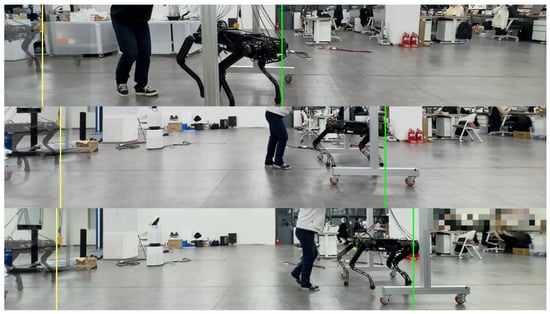
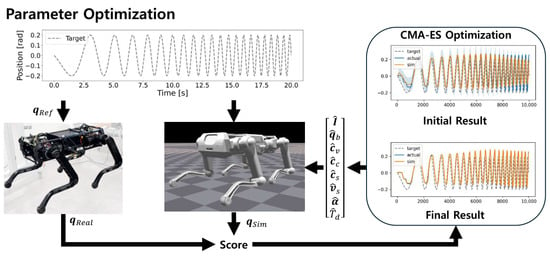
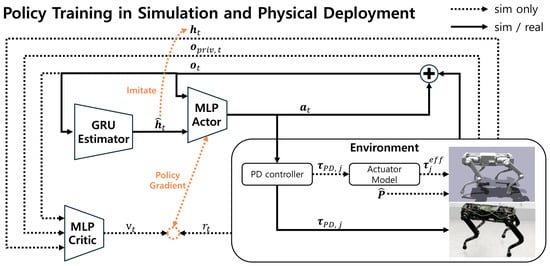
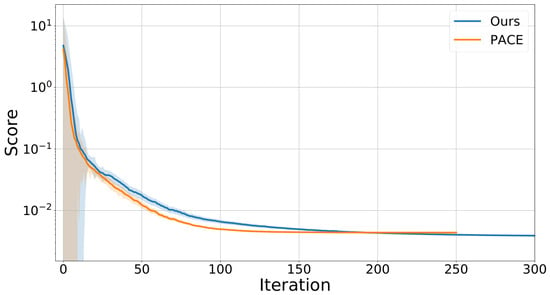
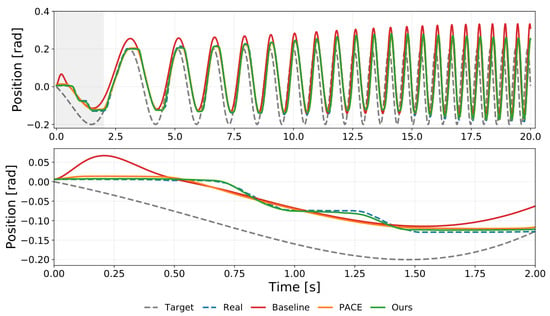
Reinforcement learning (RL) has become a powerful tool for quadrupedal locomotion, and a sim-to-real approach is widely adopted to avoid hardware damage during training. However, the “sim-to-real gap” remains a critical challenge, particularly for robots driven by high-gear-ratio actuators, in which nonlinear friction effects are strongly amplified. Conventional methods, such as actuator networks or heuristic domain randomization, often require specialized sensors or extensive trial-and-error to tune appropriate randomization ranges. Building on a recent system-identification framework for actuator dynamics, we extend it with an augmented friction model that incorporates the Stribeck effect to capture the low-velocity nonlinearities characteristic of high-gear-ratio actuators. The physical parameters are identified from real-robot trajectory data using an evolutionary algorithm, and the resulting simulation is used to train a locomotion policy that is transferred zero-shot to a 55 kg quadruped without additional fine-tuning or base- or controller-level dynamics randomization. On our platform, adding the Stribeck term lowers the actuator identification error by 16% relative to a Coulomb–Viscous model on the trajectory used for identification, and this advantage generalizes to an unseen trajectory not used for identification. It also lowers the simulation-to-reality mean-velocity degradation from 40.2% and 26.8% for the Coulomb–Viscous model to 27.2% and 21.6% for our method at the 0.3 and 1.0 m/s commands, respectively. The trained policy achieves stable locomotion on flat ground as well as rough terrain including steps and stairs. These results indicate that explicitly modeling low-velocity friction is beneficial for high-fidelity sim-to-real transfer in high-reduction systems.
Full article
(This article belongs to the Special Issue The Future of Mobility: Exploring Wheeled–Legged Robot Systems)
►
Show Figures
Open AccessArticle
Stage-Aware Multi-Task Learning with Causal Degradation-Prior Fusion for Remaining Useful Life Prediction
by
Lei Song, Chuanhao Zheng, Shengkai Zhao, Qin Bie, Zhixiang Dai, Feng Wang, Jinjie Zhang and Jiachen Liu
Machines 2026, 14(9), 1030; https://doi.org/10.3390/machines14091030 - 9 Sep 2026
Abstract
Remaining useful life (RUL) prediction of wind-turbine bearings is challenged by nonstationary wind loads, multistage degradation, substantial lifetime dispersion, and strict deployment constraints. Conventional single-task regressors apply a unified feature-to-RUL mapping over the entire life cycle and therefore struggle to characterize stage transitions
[...] Read more.
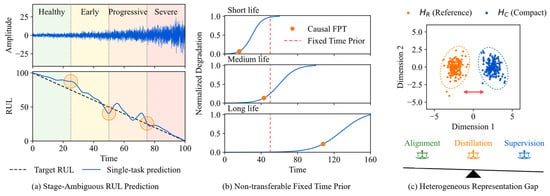
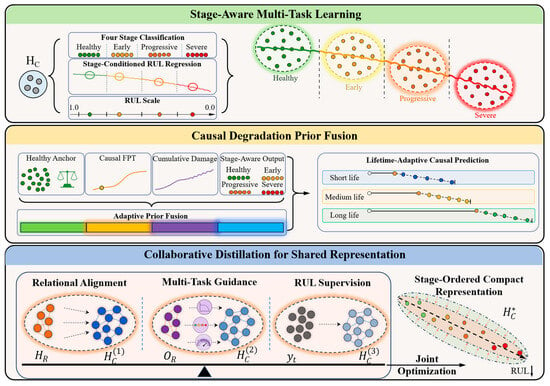
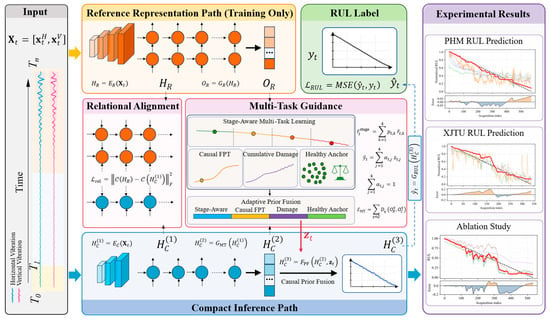
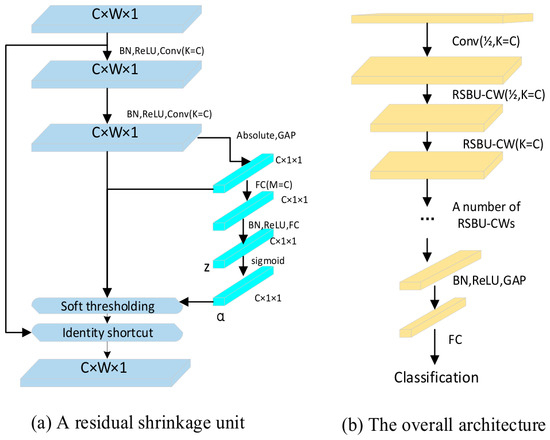
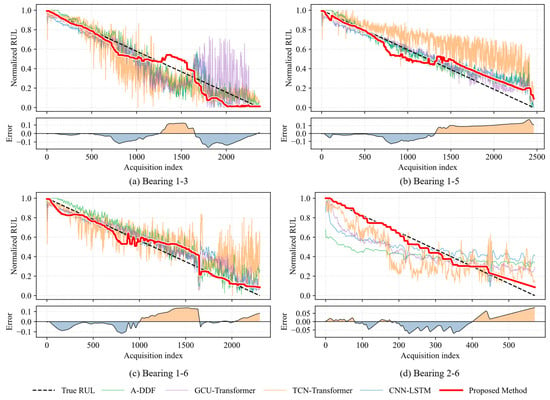
Remaining useful life (RUL) prediction of wind-turbine bearings is challenged by nonstationary wind loads, multistage degradation, substantial lifetime dispersion, and strict deployment constraints. Conventional single-task regressors apply a unified feature-to-RUL mapping over the entire life cycle and therefore struggle to characterize stage transitions and bearing-specific degradation progress. To address these issues, this paper proposes a stage-aware multi-task RUL prediction method with causal degradation-prior fusion and collaborative distillation. During training, a high-capacity reference representation path transfers inter-sample relational structures and task-level degradation knowledge to a compact feature encoding path, while only the compact path is retained for inference. Based on the compact representation, a multi-task module jointly performs four-stage classification, stage-conditioned RUL regression, and continuous remaining-life estimation; predicted stage probabilities softly fuse the stage-conditioned outputs. A causal prior-fusion module further integrates a bearing-specific healthy-state anchor, causally identified first prediction time, cumulative damage, and the stage-aware prediction to adapt the RUL trajectory to individual degradation processes. Experiments on the IEEE PHM 2012 and XJTU-SY datasets demonstrate that the proposed method provides accurate and robust RUL prediction across different bearing degradation processes. Moreover, the compact inference path maintains efficient implementation, supporting its potential use in practical wind-turbine condition-monitoring applications.
Full article
(This article belongs to the Special Issue Health Condition Monitoring, Intelligent Operation and Maintenance of Wind Turbines)
►▼
Show Figures

Figure 1

Open AccessArticle
A Numerical Study of a Water–Steam Ejector for Steam Exhausting with OpenFoam—The Effect of Steam-Bubble Diameter
by
Mercè Garcia-Vilchez, Robert Castilla, Arne Hauschildt, Carmen Carrillo and Pedro Javier Gamez-Montero
Machines 2026, 14(9), 1029; https://doi.org/10.3390/machines14091029 - 9 Sep 2026
Abstract
A water–steam ejector can be used for steam exhausting in some equipment, such as sterilization systems in hospital facilities. In this type of ejector, a water jet in the center is used to entrain and transport steam from the sterilization chamber. The performance
[...] Read more.
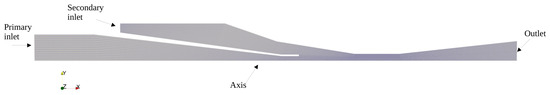
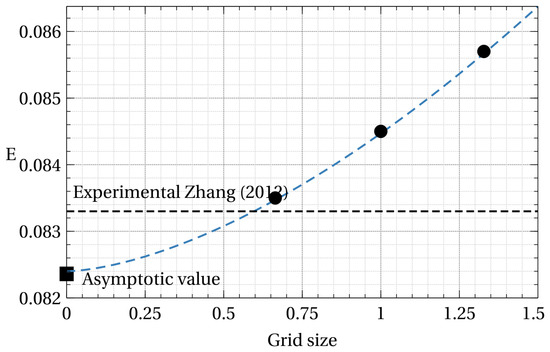
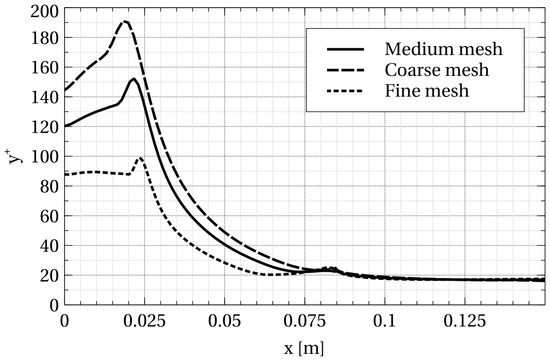
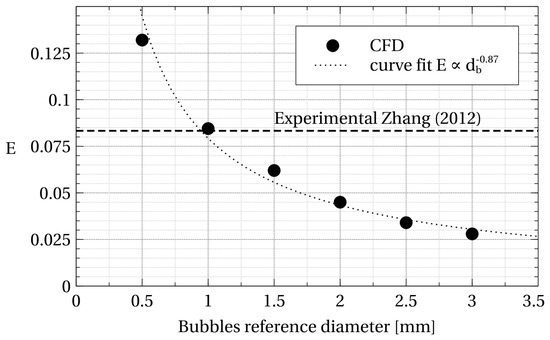
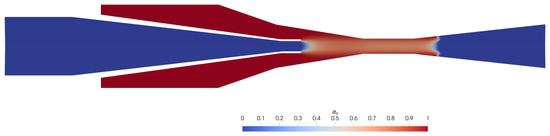
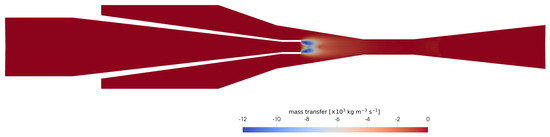
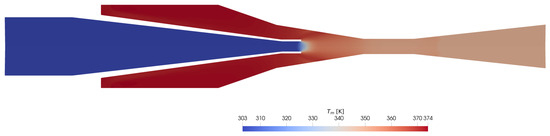
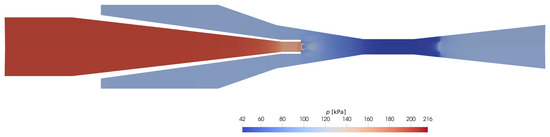
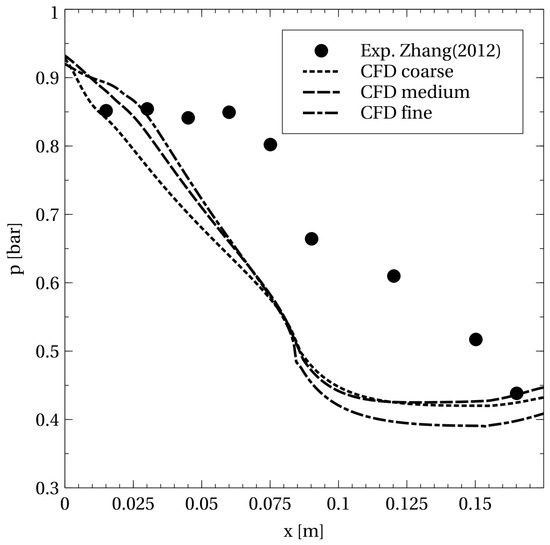
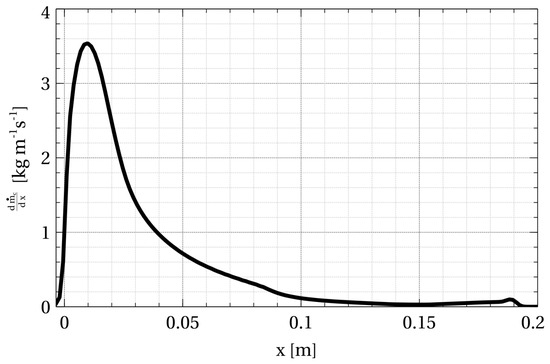
A water–steam ejector can be used for steam exhausting in some equipment, such as sterilization systems in hospital facilities. In this type of ejector, a water jet in the center is used to entrain and transport steam from the sterilization chamber. The performance of the ejector, which is a function of the pressure in the sterilization chamber and the temperature of the water, is crucial for the reduction in water and energy consumption. The numerical simulation of this type of device is challenging because of the mass, momentum and energy exchange between the phases. In this study, numerical simulations of an axisymmetrical model of a water–steam ejector considering mixing and heat and mass transfer by condensation are shown. The Euler–Euler method with OpenFOAM v2312 was used. The influence of the steam-bubble diameter was studied, and the results were validated with a previously published experimental report, which showed an agreement of approximately 2.5% for the adopted mesh size. The proposed solution may be appropriate for rapid design procedures for these types of devices.
Full article
(This article belongs to the Section Turbomachinery)
►▼
Show Figures

Figure 1
Open AccessArticle
A Low-Cost Retrofitted CNC Platform with Mobile-Terminal Control for Micro Electrical Discharge Deposition: System Design and Process Characterization
by
Zhiming Xiao, Chi Chen and Zhihao Ke
Machines 2026, 14(9), 1028; https://doi.org/10.3390/machines14091028 - 8 Sep 2026
Abstract
Micro electrical discharge deposition (micro-EDD) enables maskless direct-write metallic tracks on conductive substrates, but reported implementations rely on purpose-built machines with programmable pulse generators and gap servos. This paper reports a low-cost micro-EDD platform retrofitted from a desktop CNC router driven by GRBL
[...] Read more.
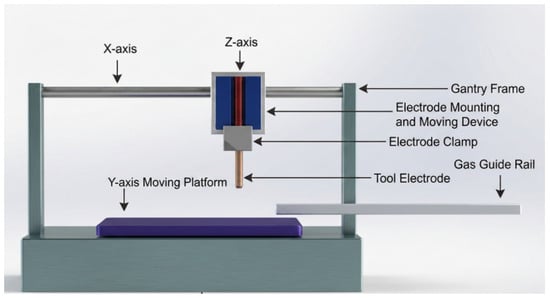
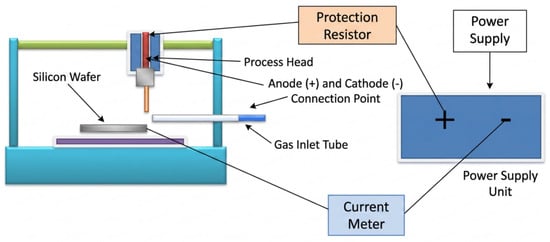
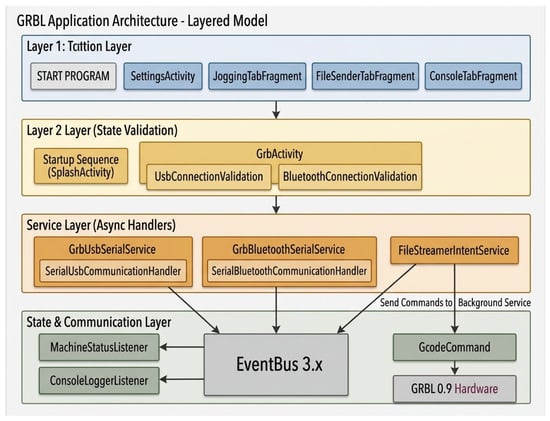
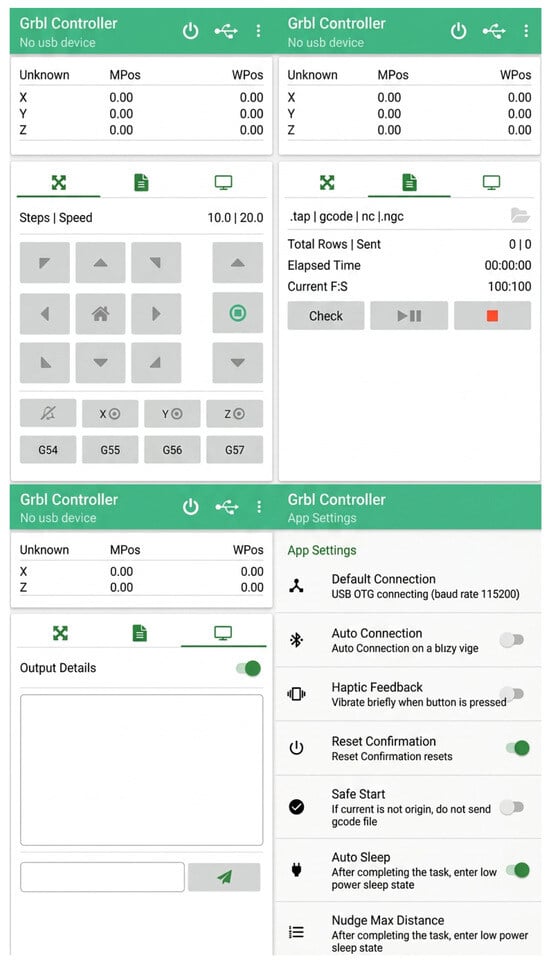
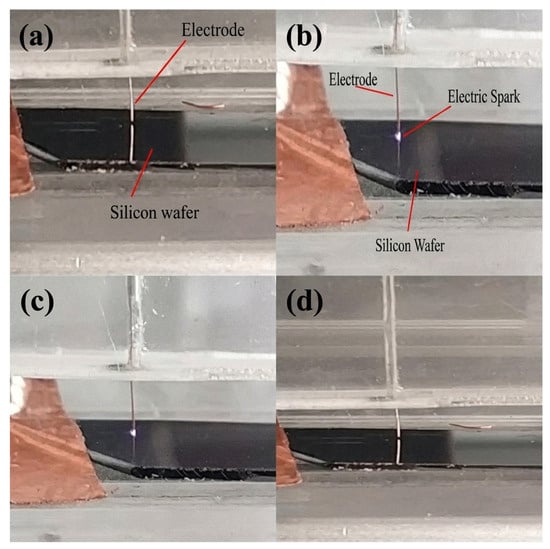
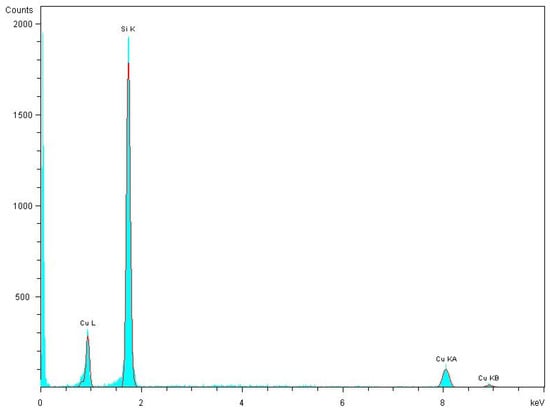
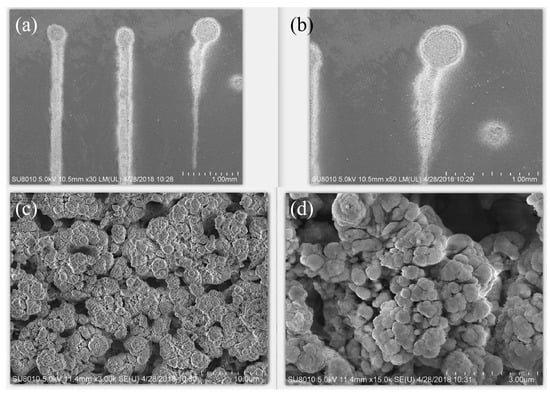
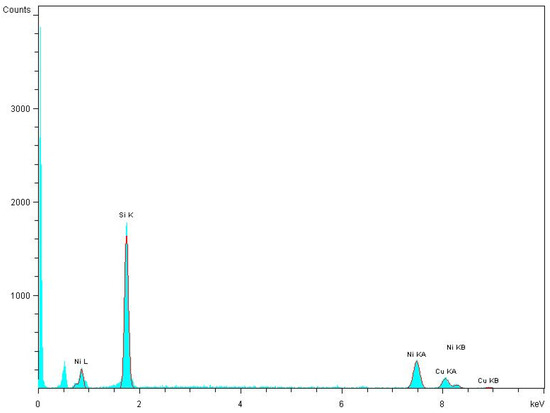
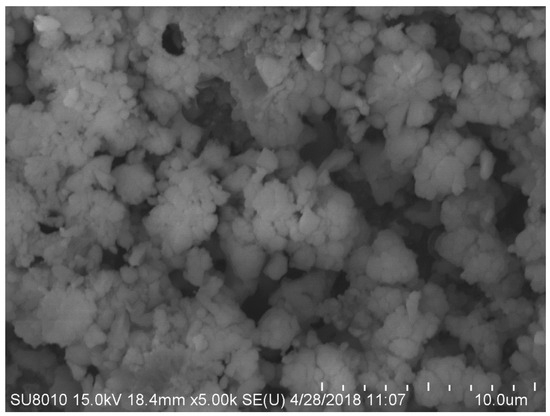
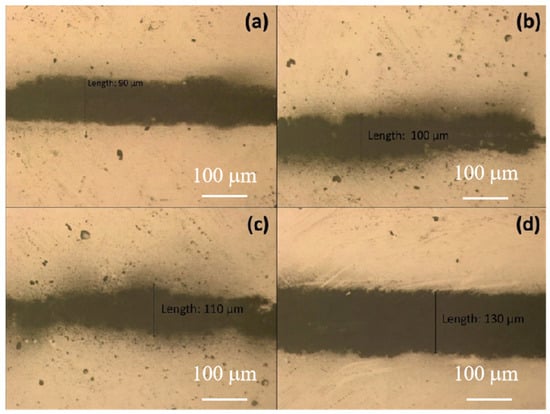
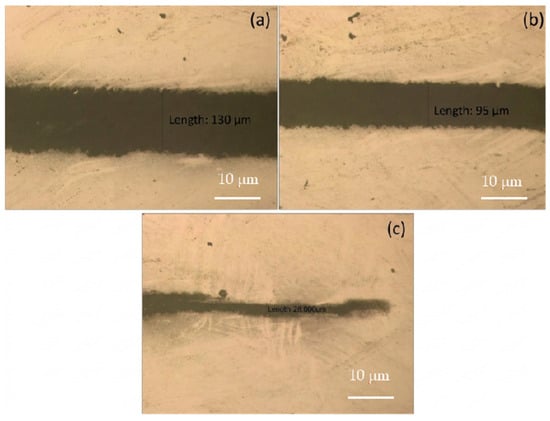
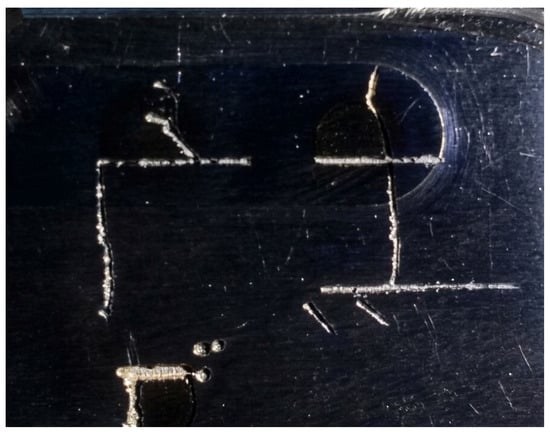
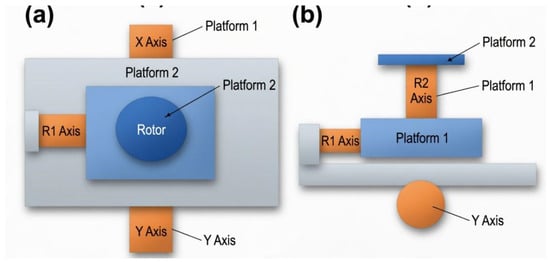
Micro electrical discharge deposition (micro-EDD) enables maskless direct-write metallic tracks on conductive substrates, but reported implementations rely on purpose-built machines with programmable pulse generators and gap servos. This paper reports a low-cost micro-EDD platform retrofitted from a desktop CNC router driven by GRBL firmware, extended with an Android control application for path definition and process supervision. Discharge is produced by an RC relaxation circuit with no pulse generator and no gap feedback. Copper, aluminium, nickel, and titanium electrodes were deposited onto silicon substrates in an argon atmosphere, maintaining a 10 μm separation. The working point, pd ≈ 0.76 Torr·cm, lies within 20% of the argon Paschen minimum. Track width rises linearly with supply voltage over 330–400 V (w = 0.570 V − 99.2 μm, R2 = 0.994), extrapolating to a deposition threshold of 174 V, 37 V above the argon breakdown minimum—indicating an energy threshold distinct from breakdown. Across electrode materials, width shows a trend consistent with thermal diffusivity as (R2 = 0.69, N = 4), resolving the inconsistency that copper, the best conductor, gives the widest track. Polarity reversal changes width by factors of 4.6 (Cu) and 7.5 (Al), consistent with anode-dominated energy partition. Péclet numbers remain below 3 × 10⁻⁴ and overlap ratios above 103, excluding thermal advection and insufficient overlap as causes of the feed-rate collapse. A five-axis kinematic extension is derived, with Z travel identified as the bounding constraint.
Full article
(This article belongs to the Section Advanced Manufacturing)
►▼
Show Figures

Figure 1
Open AccessArticle
Lightweight Design of the Baffle Structure in a High-Speed-Train Water Tank Based on an Improved Multi-Objective Particle Swarm Optimization Algorithm
by
Sihui Dong, Yuebiao Zhao, Xingyu Zhou and Wenhao Bai
Machines 2026, 14(9), 1027; https://doi.org/10.3390/machines14091027 - 8 Sep 2026
Abstract
Lightweight design of high-speed-train water tanks can easily lower the natural frequency of baffles, increasing the risk of resonance and fatigue failure and thus threatening operational safety. To address this issue, a lightweight optimization method that does not reduce the first-order natural frequency
[...] Read more.
Lightweight design of high-speed-train water tanks can easily lower the natural frequency of baffles, increasing the risk of resonance and fatigue failure and thus threatening operational safety. To address this issue, a lightweight optimization method that does not reduce the first-order natural frequency of the baffle is proposed, taking a suspended water tank of a certain type of CRH electric multiple unit (EMU) as the research object. First, a two-way fluid–structure interaction (FSI) finite element model was established based on the computational fluid dynamics (CFD) method. The design of experiments method was employed to determine the optimal number of baffles inside the tank, and the response surface methodology was applied to construct quadratic polynomial surrogate models for baffle mass, maximum water tank stress, baffle deformation, and the first-order natural frequency. Analysis of variance was conducted to verify the fitting accuracy and significance of each model. After clarifying the influence of design variables on the response indicators, and to overcome the shortcomings of the standard multi-objective particle swarm optimization (MOPSO) algorithm, such as susceptibility to local optima, simplistic constraint handling, and premature convergence, an improved multi-objective particle swarm optimization (IMOPSO) algorithm integrating chaotic initialization, adaptive parameter adjustment, and a dynamic mutation strategy was proposed. With the first-order natural frequency serving as a constraint, multi-objective optimization of the baffle structure was carried out. Finally, the prediction accuracy of the surrogate models was numerically validated using finite element simulation software. The results show that after optimization, the baffle mass was reduced by 16.13%, the first-order natural frequency increased by 0.41 Hz (by FEM), the maximum water tank stress decreased by 288 Pa (by FEM), and the baffle deformation was reduced by 7.66% according to FEM verification (RSM surrogate-model prediction gave a reduction of 9.07%). The maximum prediction error of the surrogate models was only 1.53%, confirming the effectiveness and feasibility of the proposed method. This study can provide a theoretical basis and engineering reference for the improvement and performance optimization of water tanks on CRH EMUs and other similar tank structures.
Full article
(This article belongs to the Section Vehicle Engineering)
Open AccessArticle
ACR-Nav: Localization-Free Corridor Navigation via Action-Conditioned Scalar-Range Evolution
by
Qiguang Shen, Zhaoyue Wang, Yifei Feng and Kun Xu
Machines 2026, 14(9), 1026; https://doi.org/10.3390/machines14091026 - 8 Sep 2026
Abstract
Mapless navigation often removes global maps while retaining localization-derived goal vectors or bearings. We study a stricter setting in which a mobile robot observes only local LiDAR, scalar goal range, and short histories of executed actions; neither pose nor goal direction is provided
[...] Read more.
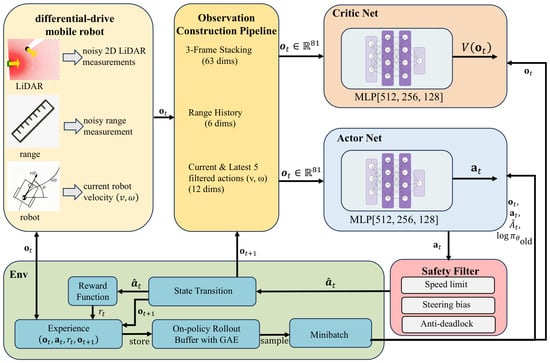
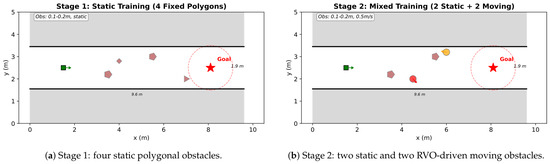
Mapless navigation often removes global maps while retaining localization-derived goal vectors or bearings. We study a stricter setting in which a mobile robot observes only local LiDAR, scalar goal range, and short histories of executed actions; neither pose nor goal direction is provided to the policy. We introduce ACR-Nav, an action-conditioned range navigation framework that converts scalar-range evolution into closed-loop progress information. Its range–action history associates each distance change with the motion that produced it, while the sectorized LiDAR captures local geometry and short-term obstacle motion. A LiDAR-only safety filter provides immediate collision intervention, and a static-to-mixed curriculum stabilizes learning. A lightweight multilayer–perceptron is optimized with Proximal Policy Optimization (PPO), while the ACR-Nav formulation itself remains optimizer-agnostic. In corridor simulations, ACR-Nav achieved 93.2%, 80.4%, and 84.4% success in static, mixed, and dynamic environments. Removing the safety filter reduced success by 15.2, 14.6, and 16.0 percentage points in static, mixed, and dynamic environments, respectively, and random-goal tests yielded 91.2% and 81.4% success in static and mixed settings. Topology-shift experiments further quantified adaptation to an L-shaped corridor. The results show that action-conditioned scalar-range evolution can support goal-directed, segment-level navigation within locally straight corridor passages without exposing robot pose or target bearing to the policy.
Full article
(This article belongs to the Special Issue Advanced Planning, Perception, and Control for Autonomous Vehicles and Robots)
►▼
Show Figures

Figure 1
Open AccessArticle
Example Case of a High-Speed Gearbox Concept for E-Mobility with a Sequentially Phased Planetary Stage Focusing on NVH Measurements
by
Alex Ueberbacher, Andreas Auer, Stefan Sendlbeck, Michael Otto and Karsten Stahl
Machines 2026, 14(9), 1025; https://doi.org/10.3390/machines14091025 - 8 Sep 2026
Abstract
The increasing performance requirements of electric vehicle powertrains demand lightweight, efficient, and low-noise transmission systems. High-speed electric drive unit concepts offer significant potential for reducing motor size and mass by shifting torque generation to higher rotational speeds. However, this approach places increased demands
[...] Read more.
The increasing performance requirements of electric vehicle powertrains demand lightweight, efficient, and low-noise transmission systems. High-speed electric drive unit concepts offer significant potential for reducing motor size and mass by shifting torque generation to higher rotational speeds. However, this approach places increased demands on gearbox power density, efficiency, and noise, vibration, and harshness (NVH) performance. This work investigates the NVH behaviour of a compact, high-speed automotive gearbox with a focus on planetary gear stages. Although planetary stages offer high compactness, their complex kinematics can lead to pronounced NVH challenges. In particular, sequentially phased gear meshing results in characteristic sideband components whose orders can be predicted analytically, while their amplitudes remain difficult to estimate reliably during the design phase, necessitating experimental validation. Several NVH-oriented design measures, including high-contact-ratio gearing and low-NVH microgeometry, are applied to a two-stage gearbox comprising a planetary and a cylindrical gear stage. Peak-to-peak transmission error is used as a primary NVH design metric. The planetary stage is analysed in detail to assess the influence of sequential phasing on sideband components in the dynamic response and resulting vibration behaviour. The NVH-oriented gearbox is tested on a bench, with housing accelerations used to analyse planetary sidebands, providing insights into the NVH potential of compact, high-speed gearboxes and the role of sequential phasing in the vibration response.
Full article
Open AccessArticle
Comparative Evaluation of Conventional Feature-Based and Physics-Guided Condition-Index Representations for Industrial Motor Fault Diagnosis
by
DongHee Park, JaeGwang Yoon and ByeongKeun Choi
Machines 2026, 14(9), 1024; https://doi.org/10.3390/machines14091024 - 8 Sep 2026
Abstract
This study compares a conventional feature-based representation and a physics-guided condition-index (CI) representation for vibration-based fault diagnosis of industrial motors. Both representations were constructed from identical vibration signal segments and evaluated under the same classification conditions using support vector machine (SVM) classifiers. For
[...] Read more.
This study compares a conventional feature-based representation and a physics-guided condition-index (CI) representation for vibration-based fault diagnosis of industrial motors. Both representations were constructed from identical vibration signal segments and evaluated under the same classification conditions using support vector machine (SVM) classifiers. For each representation, a genetic algorithm (GA) was repeatedly applied to the training data to select three representative variables, after which the SVM hyperparameters were optimized using three-fold cross-validation. Permutation Importance and SHapley Additive exPlanations (SHAP) were subsequently used to interpret the contributions of the selected CIs. Independent test motors, whose fault conditions had been established through manufacturer troubleshooting before the present analysis, were excluded from all model-development procedures. For the independent Unbalance and Misalignment test motors, the CI-based model achieved segment-level classification rates of 99.83% and 100%, respectively, whereas the conventional representation showed substantial misclassification. Because these segments originated from a single physical motor for each fault condition, the reported rates represent within-motor segment-level outcomes rather than population-level estimates of diagnostic performance. FFT analysis revealed dominant 1X and 2X components in the corresponding test data, consistent with their established fault conditions. For an additional independent motor identified as Air-gap Unbalance, the CI-based model classified all test segments as Air-gap Unbalance, while the FFT spectrum exhibited fractional-frequency characteristics similar to those observed in the corresponding fault data. Overall, the physics-guided CI representation produced classification outcomes that were more consistent with the established fault conditions and provided a more physically interpretable basis for model decisions under the industrial motor conditions examined in this study.
Full article
(This article belongs to the Section Electrical Machines and Drives)
►▼
Show Figures

Graphical abstract
Open AccessArticle
Improved TOPSIS and CRITIC Methods for Failure Mode and Effects Analysis Based on Z-Number Theory
by
Daijun Deng, Shuai Jiang, Xinlong Li, Yu Liu, Ning Wei and Fafa Chen
Machines 2026, 14(9), 1023; https://doi.org/10.3390/machines14091023 - 8 Sep 2026
Abstract
Failure mode and effects analysis (FMEA), as a means of identifying, preventing, and controlling potential system failures, has been widely applied in many industries. However, the classic FMEA method has several drawbacks in practical applications, such as the uncertainty and ambiguity in the
[...] Read more.
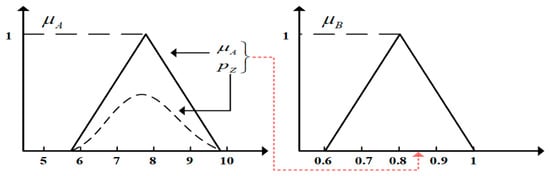
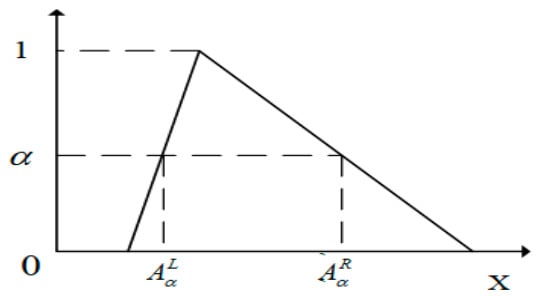
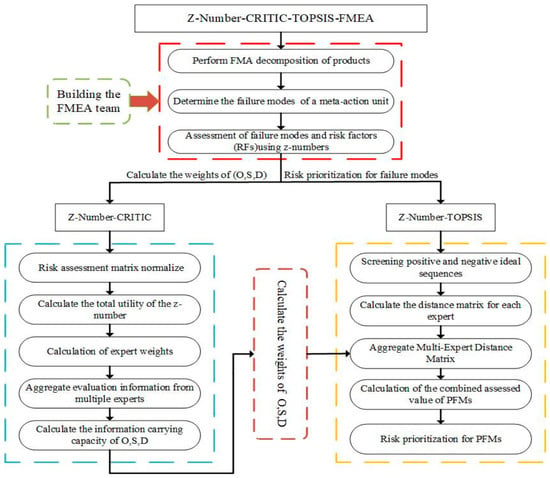
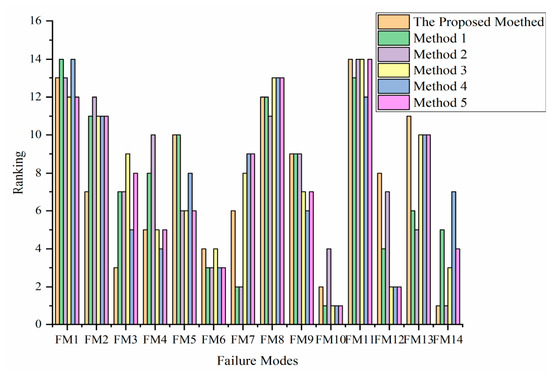
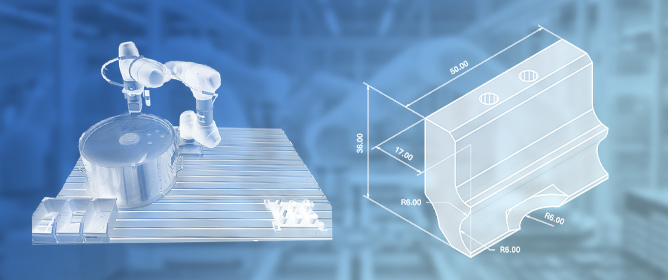
Failure mode and effects analysis (FMEA), as a means of identifying, preventing, and controlling potential system failures, has been widely applied in many industries. However, the classic FMEA method has several drawbacks in practical applications, such as the uncertainty and ambiguity in the expression of evaluation information, the neglect of the reliability of evaluation information, and the failure to consider the psychological behavior of experts, which leads to inaccurate evaluation results. Therefore, this paper proposes an improved FMEA framework that integrates Z-number theory with the criteria importance through intercriteria correlation (CRITIC) and technique for order preference by similarity to ideal solution (TOPSIS) methods to improve the accuracy of failure mode risk ranking. Specifically, Z-numbers are employed to represent expert assessment information, effectively capturing both fuzziness and reliability. The CRITIC method is then extended with Z-numbers to determine the weights of risk factors, which not only accounts for the interrelationships among factors but also prevents information loss caused by defuzzification of weights. Moreover, to handle missing assessment data, a generalized Z-number distance measure is introduced, and the TOPSIS model is enhanced to rank failure modes by considering the reliability and uncertainty of the information. Finally, the effectiveness of the proposed method is verified by taking the pallet exchange device of a CNC machine tool as an example. The results show that, compared with other FMEA methods, the proposed method considers the reliability and fuzziness of the evaluation information, maintains the original Z-number information structure, and provides more accurate and reliable risk-ranking results.
Full article
(This article belongs to the Section Automation and Control Systems)
►▼
Show Figures

Figure 1
Open AccessArticle
Weld-FHG-YOLO: A Lightweight Multi-Frequency Feature Fusion Network for Weld Keypoint Localization
by
Yunsong Yan, Xiaoning Meng, Wei Liu, Hougao Wang, Haiyang Liu, Chao Chen and Fuxin Du
Machines 2026, 14(9), 1022; https://doi.org/10.3390/machines14091022 - 7 Sep 2026
Abstract
Accurate weld keypoint localization is an important visual perception task for robotic welding, weld tracking, and intelligent manufacturing. However, weld keypoints in line-structured light images are usually small, weakly textured, and easily affected by reflections, noise, and spurious laser stripes. These factors make
[...] Read more.
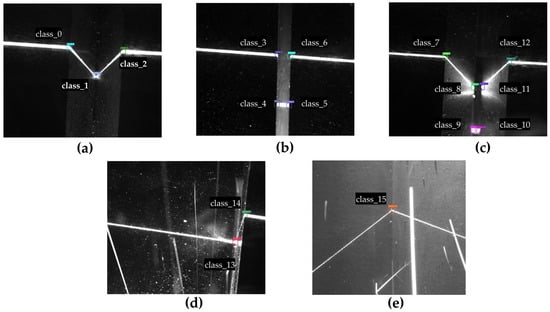
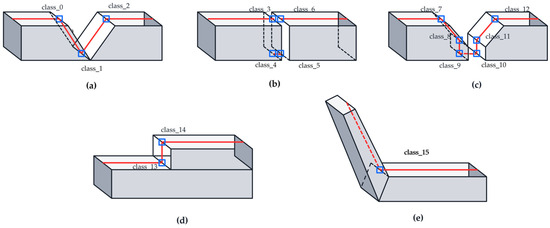
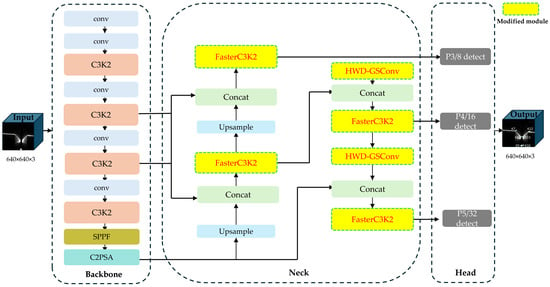
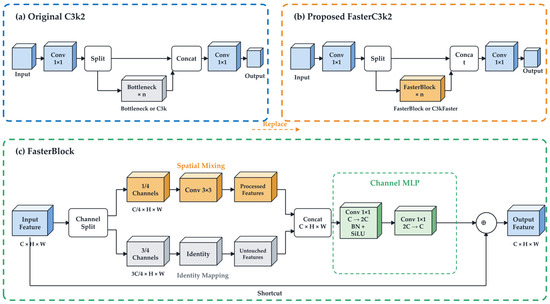
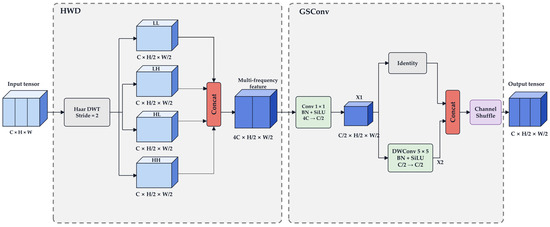
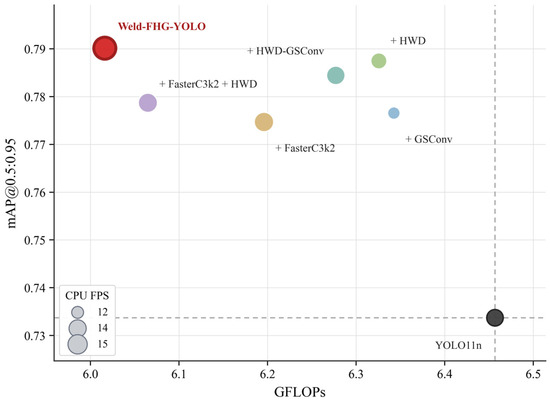
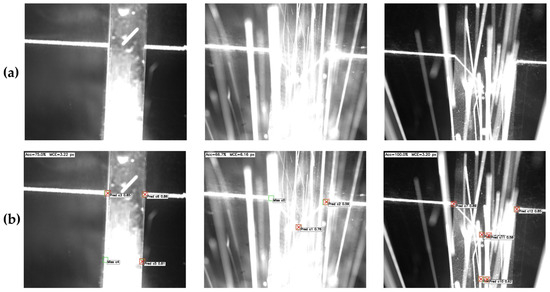
Accurate weld keypoint localization is an important visual perception task for robotic welding, weld tracking, and intelligent manufacturing. However, weld keypoints in line-structured light images are usually small, weakly textured, and easily affected by reflections, noise, and spurious laser stripes. These factors make it difficult for lightweight detection models to balance localization accuracy and computational efficiency. To address this problem, this paper proposes Weld-FHG-YOLO, a lightweight multi-frequency feature fusion network for weld keypoint localization. The proposed model is built on the You Only Look Once version 11 nano (YOLO11n) framework and focuses on optimizing feature fusion and scale transformation in the Neck. Specifically, FasterC3K2 is introduced to replace the original C3K2 modules in the Neck, thereby reducing redundant computation during multi-scale feature fusion. In addition, a Haar Wavelet Decomposition and Group Shuffle Convolution (HWD-GSConv) downsampling fusion module is designed, in which Haar wavelet decomposition preserves low-frequency structural information and high-frequency details, while GSConv performs lightweight multi-frequency feature fusion. Experimental results show that Weld-FHG-YOLO achieves 2.301 M parameters and 6.016 GFLOPs, which are 11.26% and 6.83% lower than those of YOLO11n, respectively. Meanwhile, mAP@0.5:0.95 increases from 0.7337 to 0.7901, the Mean Center Error (MCE) decreases from 2.254 px to 2.131 px, and the CPU inference speed increases from 13.69 to 14.77 frames per second (FPS). These results indicate that the proposed method improves strict localization accuracy and localization stability while maintaining a lightweight computational profile, providing a practical visual perception approach for weld keypoint localization in resource-constrained intelligent manufacturing scenarios.
Full article
(This article belongs to the Section Robotics, Mechatronics and Intelligent Machines)
►▼
Show Figures

Figure 1
Open AccessArticle
Singular Value-Based Analysis of Current Decoupling Control Effect of Permanent Magnet Synchronous Motors
by
Tianyi Zhang, Qi Li, Pengbin Xu, Dafang Wang, Haoyu Zhou and Jinhuan Zhao
Machines 2026, 14(9), 1021; https://doi.org/10.3390/machines14091021 - 7 Sep 2026
Abstract
The dq-axis coupling effect significantly influences the vector control performance of permanent magnet synchronous motors (PMSMs), and traditional proportional-integral (PI) control cannot control the system as desired. Extensive studies have addressed this coupling effect. However, traditional evaluation methods based on pole–zero distribution are
[...] Read more.
The dq-axis coupling effect significantly influences the vector control performance of permanent magnet synchronous motors (PMSMs), and traditional proportional-integral (PI) control cannot control the system as desired. Extensive studies have addressed this coupling effect. However, traditional evaluation methods based on pole–zero distribution are not intuitive, which is unfavorable for engineers to select and apply decoupling strategies. This paper employed singular value analysis to assess coupling trends and magnitude–frequency characteristics of the system. In consideration of the effects of rotor speed, parameter estimation error, and digital delay, a comprehensive evaluation of controllers was conducted. This evaluation included feedforward, feedback, and internal model control (IMC) decoupling, with the analysis facilitated by singular value plots. Under the parameters chosen in this paper, the feedforward decoupling controller improves slightly in decoupling under time delay, but higher rotor speed degrades its performance more. The feedback decoupling controller worsens as the system’s overshoot rate surges from 19.4% to 33.4% under the effect of time delay, though it can decouple completely under ideal conditions. It is evident that the efficacy of all strategies is diminished in the presence of parameter estimation deviation. In contrast, the internal model decoupling controller shows better decoupling capability and stronger robustness, while its overshoot remains under 24%. The effectiveness of the proposed method was confirmed through a combination of simulations and experiments.
Full article
(This article belongs to the Special Issue Advanced Control and Fault Diagnosis in Electrical Drives)
Open AccessArticle
Integrated Multi-Criteria Control of a Dual-Channel Electric Pump-Fed Propellant Feed System for a Small Liquid Rocket Engine Under Energy and Thermal Constraints
by
Kenzhebek Myrzabekov, Alina Fazylova, Kuanysh Alipbayev, Akylbek Bapyshev and Teodor Iliev
Machines 2026, 14(9), 1020; https://doi.org/10.3390/machines14091020 - 7 Sep 2026
Abstract
Electric pump-fed liquid rocket engines require coordinated propellant delivery under coupled hydraulic, electrical, actuator, and thermal constraints. This study develops an integrated reduced-order model of a dual-channel electric pump-fed propellant system, including the battery and DC bus, power converters, two independently driven motor–pump
[...] Read more.
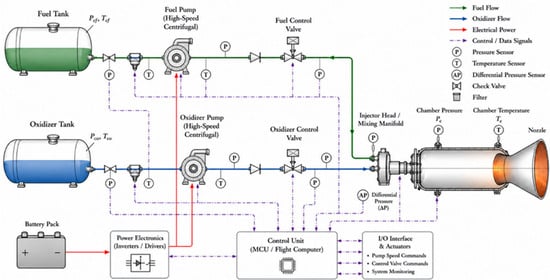
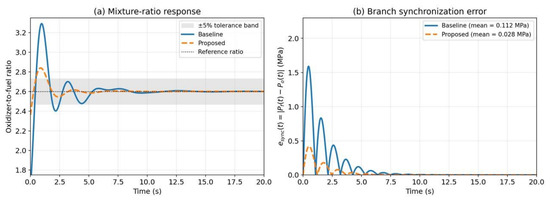
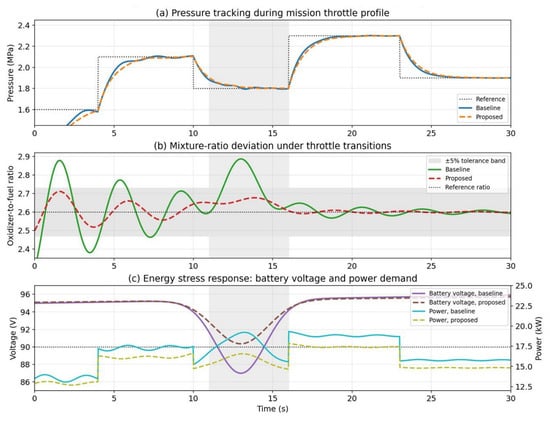
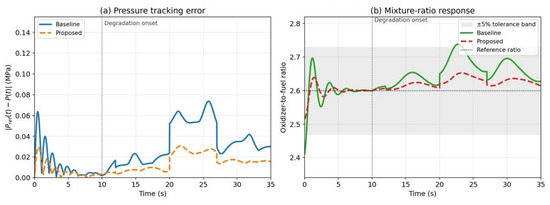
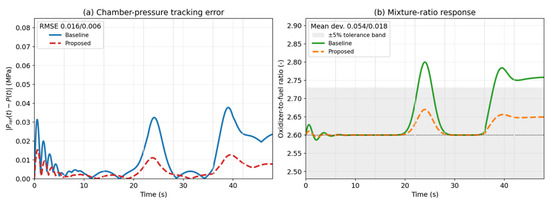
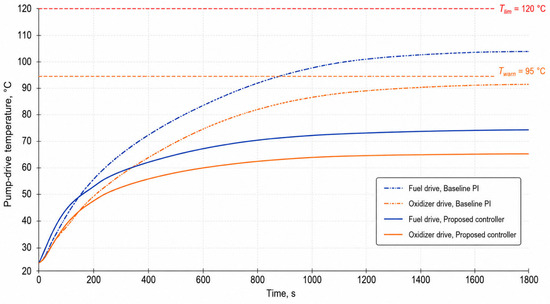
Electric pump-fed liquid rocket engines require coordinated propellant delivery under coupled hydraulic, electrical, actuator, and thermal constraints. This study develops an integrated reduced-order model of a dual-channel electric pump-fed propellant system, including the battery and DC bus, power converters, two independently driven motor–pump units, hydraulic feed lines, control valves, combustion chamber, and thermal states. A hierarchical constrained multi-criteria supervisory controller is formulated to regulate chamber pressure, oxidizer-to-fuel mixture ratio, feed-channel coordination, electrical loading, and thermal response. Performance is compared with a conventional PI controller and an enhanced PI configuration incorporating feedforward and disturbance compensation under nominal, degraded, long-duration, and constraint-active scenarios. Relative to the baseline PI controller, the proposed controller reduced the startup pressure peak from 2.64 to 2.32 MPa, pressure RMSE from 0.016 to 0.006 MPa, and mean branch synchronization error from 0.112 to 0.028 MPa. The minimum battery voltage increased from 87.0 to 90.4 V, while the peak motor current decreased from approximately 88 to 65 A. In the 1800 s thermal case, the maximum fuel-drive temperature decreased from approximately 104 to 74 °C. Numerical verification and comparison with published experimental benchmarks supported the physical plausibility and equilibrium-scale behavior of the reduced-order model, while differences in absolute transient time scales limit its use for quantitative prediction of hardware transient dynamics. The results indicate improved coordinated control within the investigated operating envelope and support the use of the framework for comparative system-level assessment and preliminary design of small-class electric-pump propulsion systems.
Full article
(This article belongs to the Section Automation and Control Systems)
►▼
Show Figures

Figure 1
Open AccessArticle
Stable and Compact Diagnostic Signatures for Demagnetization-Related Faults in BLDC/PMSM Drives: Evidence from Two Measurement Campaigns
by
Agnieszka Piątek and Jerzy Baranowski
Machines 2026, 14(9), 1019; https://doi.org/10.3390/machines14091019 - 7 Sep 2026
Abstract
This paper investigates stable and compact diagnostic feature signatures for faults related to demagnetization in brushless direct-current (BLDC) and permanent-magnet synchronous motor (PMSM) drives. Discovery analysis on the public DUDU-BLDC v1 benchmark—where DUDU is the project name derived from the Polish Diagnostyka Uszkodzeń
[...] Read more.
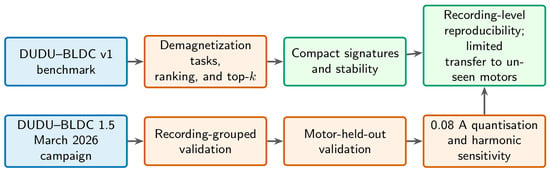
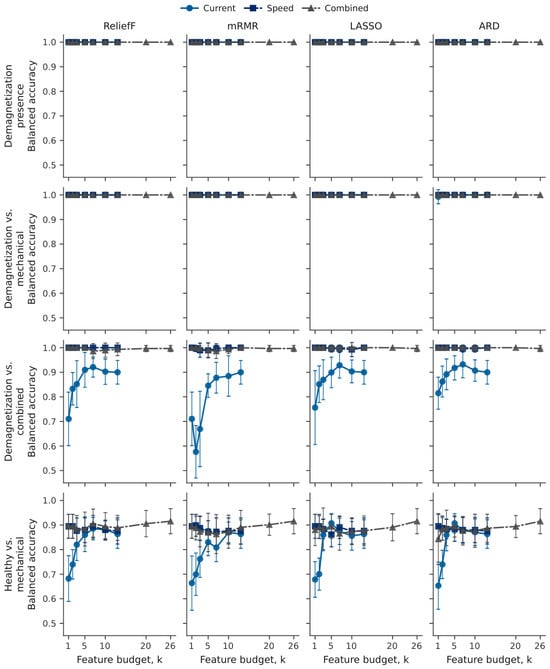
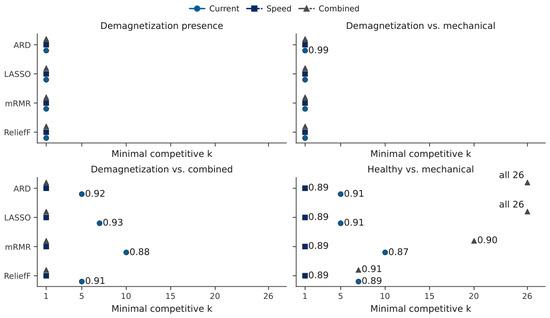
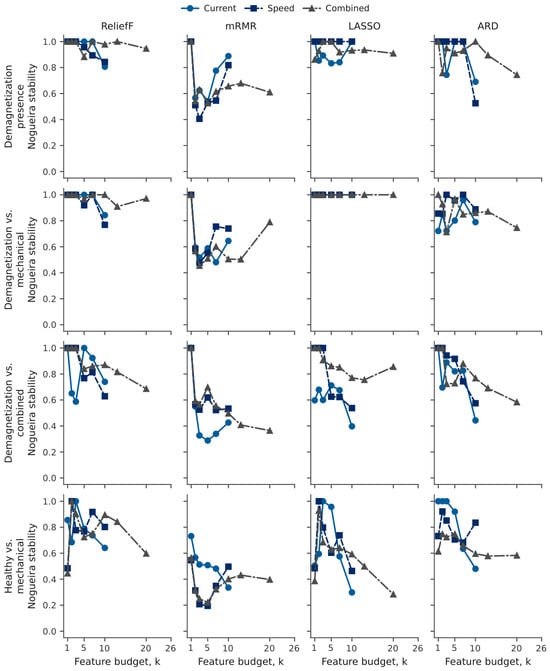
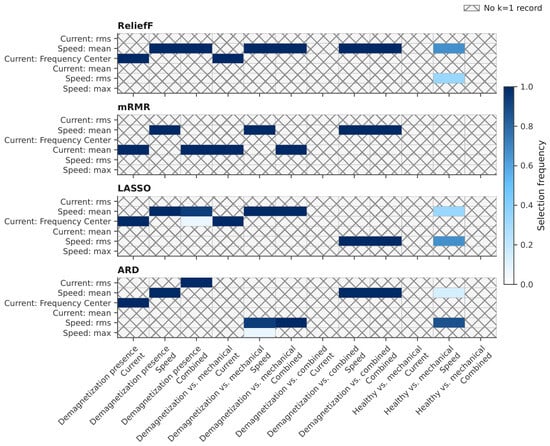
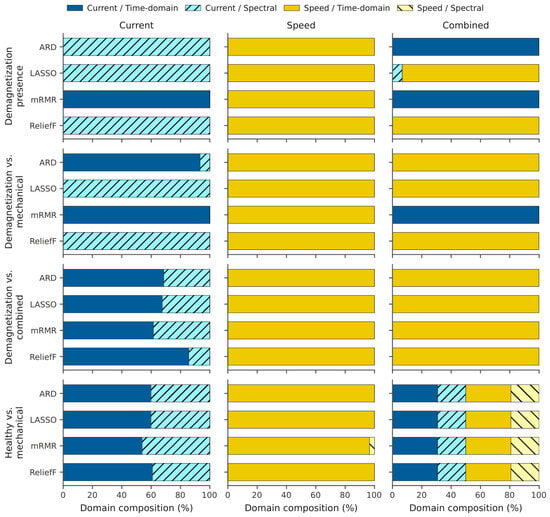
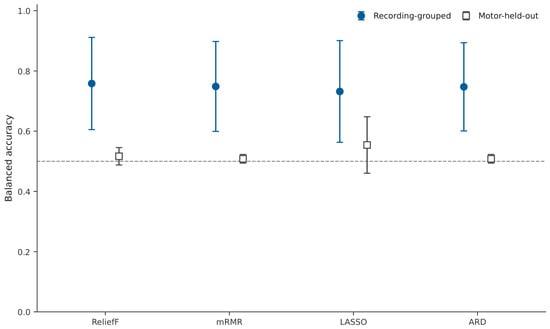
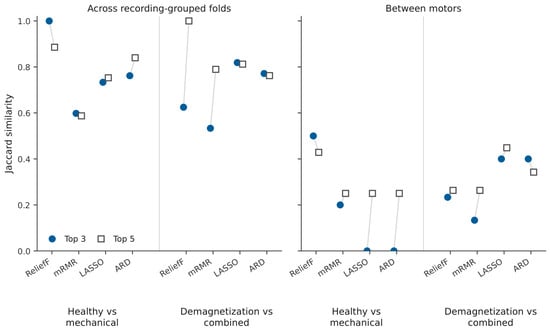
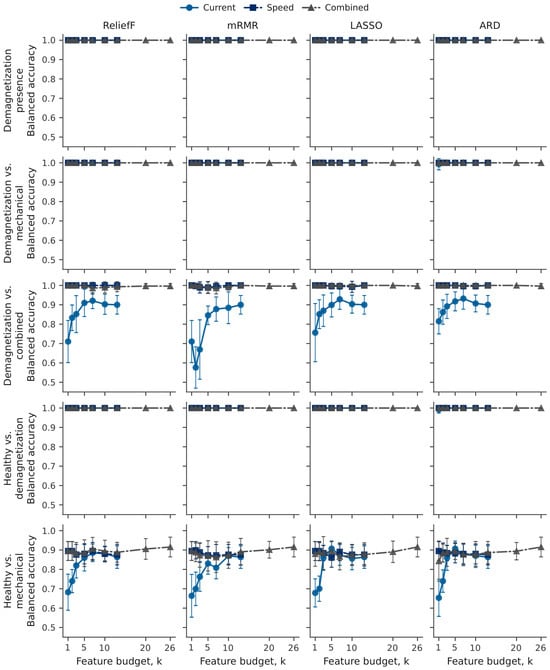
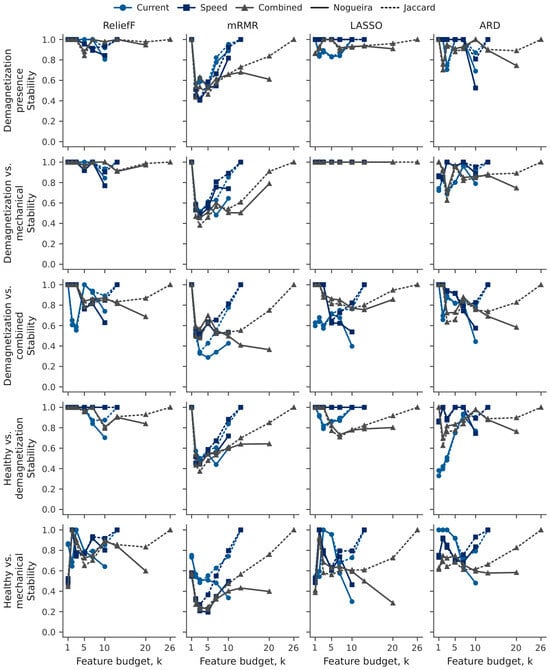
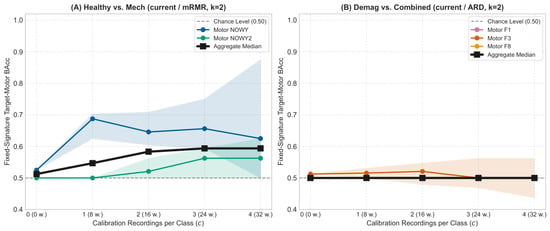
This paper investigates stable and compact diagnostic feature signatures for faults related to demagnetization in brushless direct-current (BLDC) and permanent-magnet synchronous motor (PMSM) drives. Discovery analysis on the public DUDU-BLDC v1 benchmark—where DUDU is the project name derived from the Polish Diagnostyka Uszkodzeń i Degradacji Urządzeń—compares current, speed, and combined representations under explicit top-k budgets using ReliefF, minimum-redundancy maximum-relevance (mRMR), least absolute shrinkage and selection operator (LASSO), and Bayesian automatic relevance determination (ARD) logistic ranking. The revision is accompanied by DUDU-BLDC 1.5, a new and previously unpublished March 2026 dataset comprising 50 recordings from five physical motors under altered acquisition conditions. On this second campaign, leakage-free nested five-fold recording-grouped validation with three deterministic repeats reached balanced accuracies of 0.760 and 0.758 for the two confirmatory within-motor tasks. Motor-held-out balanced accuracies fell to 0.500 and 0.554, with four of five physical-motor estimates at chance and one estimate at 0.663, exposing substantial between-motor heterogeneity. A paired experiment that quantized the original raw current signals to the approximately 0.08 A resolution of DUDU-BLDC 1.5 produced a mean absolute balanced-accuracy change of 0.0046, although the maximum change was 0.0725 and individual ranking-stability changes were larger. The results support compact signatures for repeated monitoring within an established or calibrated motor population and show aggregate robustness to reduced current resolution. They do not establish universal transfer to unseen motor instances; broader deployment requires motor-specific calibration or more diverse multi-motor training data.
Full article
(This article belongs to the Special Issue Fault Diagnostics and Fault Tolerance of Synchronous Electric Drives, 2nd Edition)
►▼
Show Figures

Figure 1
Open AccessArticle
A Two-Layer Multi-Agent Deep Reinforcement Learning Framework for Flexible Job-Shop Scheduling with Multiple Batch-Processing Machines
by
Zepeng Liu and Aimin Wang
Machines 2026, 14(9), 1018; https://doi.org/10.3390/machines14091018 - 7 Sep 2026
Abstract
Advancements in intelligent manufacturing require solutions to the conventional flexible job-shop scheduling problem (FJSP) to accommodate increasingly intricate constraints, particularly in the semiconductor and electronic component sectors, where batch-processing machines (BPMs) significantly intensify scheduling complexity. To address this challenge, this study formulates an
[...] Read more.
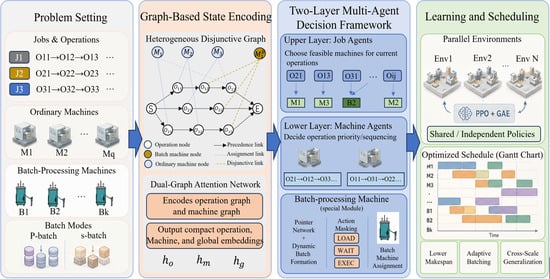
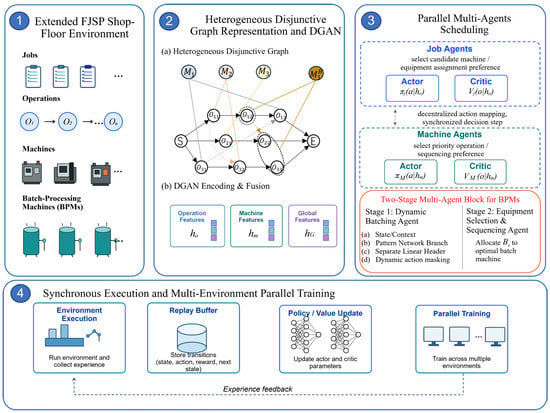
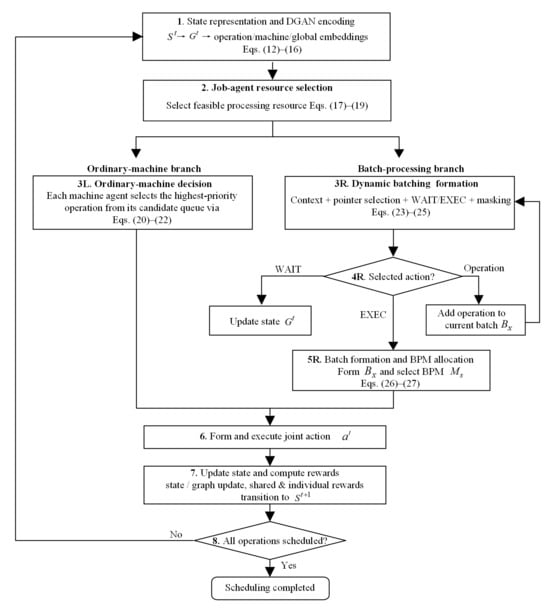
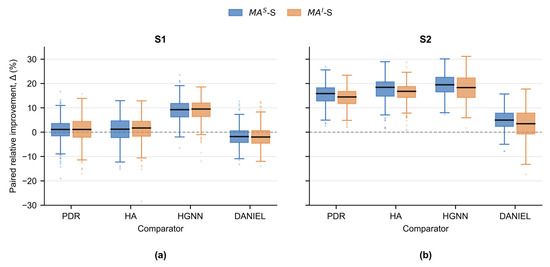
Advancements in intelligent manufacturing require solutions to the conventional flexible job-shop scheduling problem (FJSP) to accommodate increasingly intricate constraints, particularly in the semiconductor and electronic component sectors, where batch-processing machines (BPMs) significantly intensify scheduling complexity. To address this challenge, this study formulates an extended FJSP with multiple BPMs and proposes an end-to-end two-layer multi-agent deep reinforcement learning framework. Job and machine agents perform decentralized action mapping, while workshop states are encoded using a heterogeneous disjunctive graph and a dual-graph attention network. Unlike standard FJSP learning methods that primarily address operation–machine decisions, the proposed framework jointly models machine assignment, operation sequencing, variable-length batch formation, and BPM allocation within a unified policy, with a pointer network-based batching agent and an equipment-selection agent that handle batch-processing decisions under feasibility masking. The framework was validated using plant-derived production data and multi-scale synthetic instances. Numerical results show that the proposed method achieves competitive performance across the tested batching and standard-FJSP settings. In standard-FJSP comparisons, relative performance was scenario-dependent: DANIEL performed better in S1, whereas both proposed variants outperformed all comparators in S2. These results support the framework as an effective scheduling approach for deterministic FJSP with BPMs and indicate cross-scale generalization across evaluated instances.
Full article
(This article belongs to the Special Issue Intelligent Process Planning for Smart Manufacturing Systems)
►▼
Show Figures

Graphical abstract
Open AccessArticle
A Data-Driven Framework for Planetary Winch Reducer Noise Prediction via Feature Selection and Residual Compensation
by
Yiding Sun, Ling Tang, Yongsheng Zhang, Hairong Gu, Fan Li and Min Ye
Machines 2026, 14(9), 1017; https://doi.org/10.3390/machines14091017 - 7 Sep 2026
Abstract
Accurate reducer noise prediction is essential for condition monitoring and predictive maintenance of mechanical transmission systems. However, the strong nonlinear coupling between operating conditions and noise responses, together with measurement uncertainties, remains a major challenge for data-driven prediction methods. This study proposes a
[...] Read more.
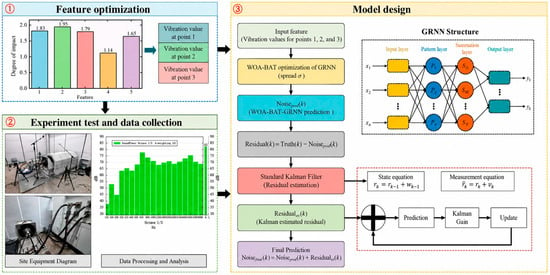
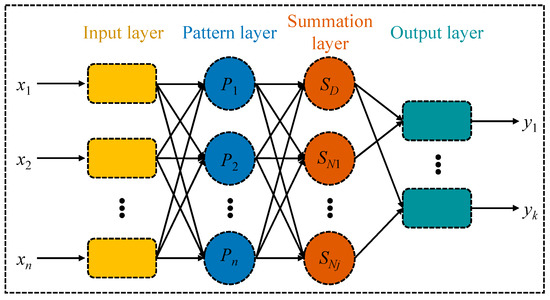
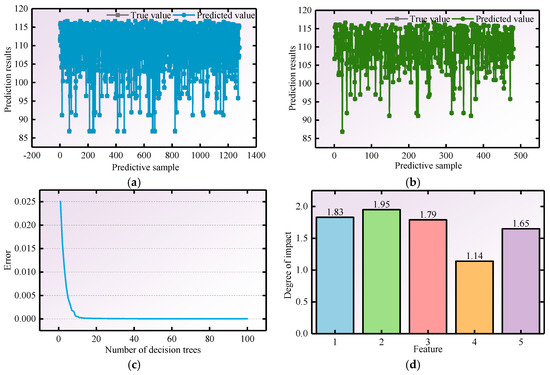
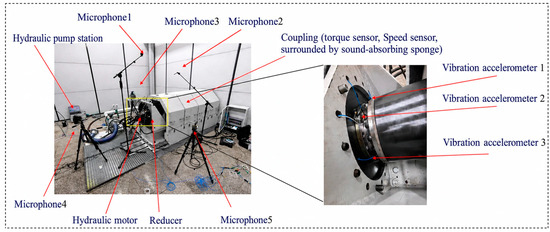
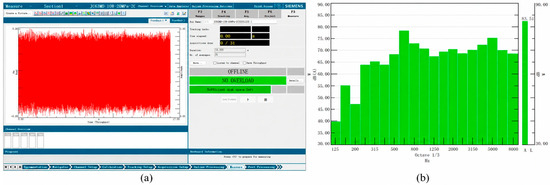
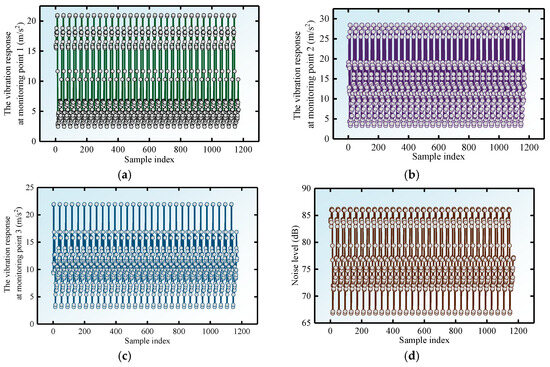
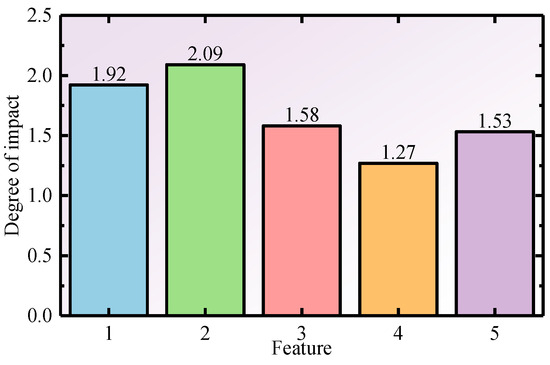
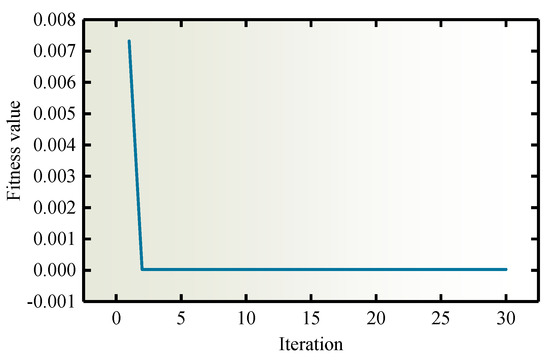
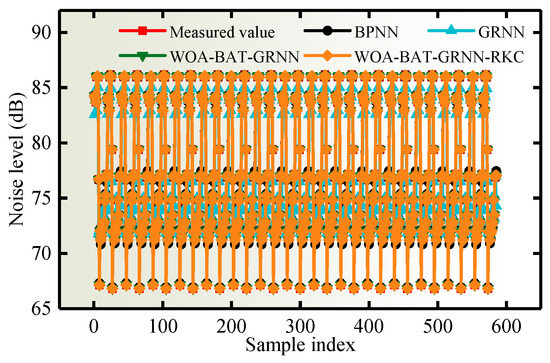
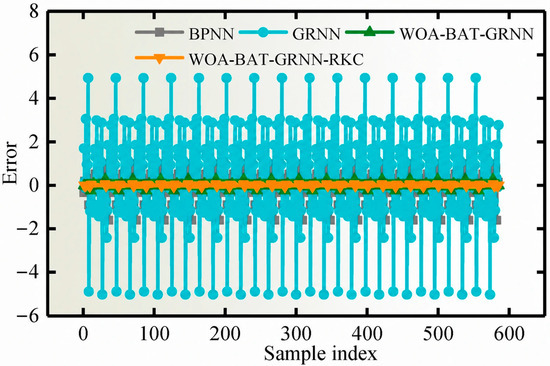
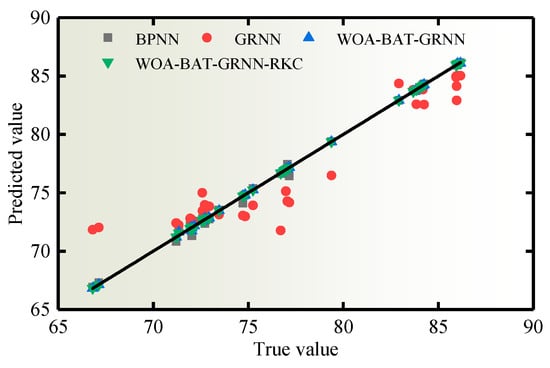
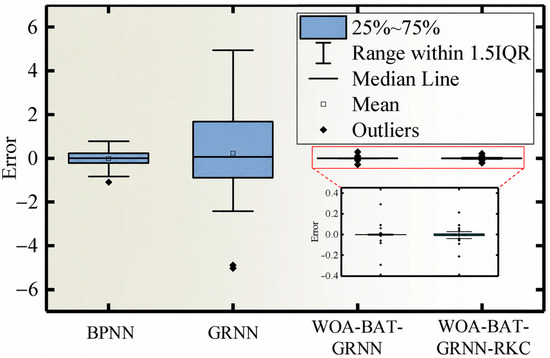
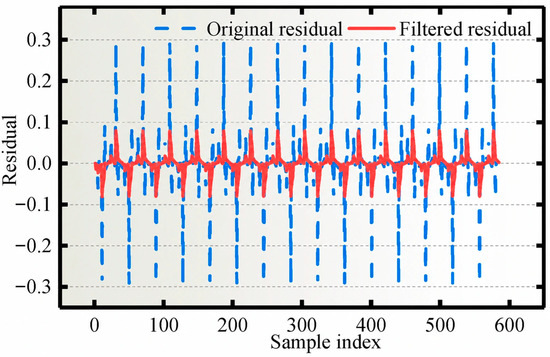
Accurate reducer noise prediction is essential for condition monitoring and predictive maintenance of mechanical transmission systems. However, the strong nonlinear coupling between operating conditions and noise responses, together with measurement uncertainties, remains a major challenge for data-driven prediction methods. This study proposes a hybrid prediction framework integrating feature selection, adaptive neural modeling, and residual compensation to improve the accuracy of planetary winch reducer noise prediction. A random forest (RF)-based feature selection strategy is first employed to identify the most informative vibration characteristics associated with reducer noise. Subsequently, a generalized regression neural network (GRNN) optimized by a hybrid whale optimization and bat algorithm (WOA-BAT) is developed to adaptively determine the smoothing factor and enhance nonlinear prediction capability. Furthermore, a residual Kalman compensation (RKC) mechanism is introduced to suppress prediction fluctuations caused by stochastic disturbances and modeling uncertainties. Experimental results demonstrate that the proposed WOA-BAT-GRNN-RKC framework achieves highly accurate noise prediction, with an RMSE of 0.05631 dB and an MAE of 0.027972 dB. The corresponding MAPE is 0.037897%. The proposed approach provides an effective pathway toward intelligent reducer condition monitoring and predictive maintenance.
Full article
(This article belongs to the Special Issue Vibration-Based Machines Wear Monitoring and Prediction, 2nd Edition)
►▼
Show Figures

Figure 1

Open AccessArticle
Physics-Guided Surrogate-Assisted Reinforcement Learning for Multi-Objective Coordinated Speed Control of a Shearer Under Complex Coal–Rock Conditions
by
Lijuan Zhao, Zhanpeng Zhang, Tiangu Wu, Yadong Wang and Shutian Gong
Machines 2026, 14(9), 1016; https://doi.org/10.3390/machines14091016 - 7 Sep 2026
Abstract
Advanced manufacturing and cutting machinery often operate under variable material properties and uncertain load conditions, making real-time process optimization difficult when high-fidelity simulations and physical experiments are costly. To address this problem, this study proposes a physics-guided surrogate-assisted reinforcement learning framework for multi-objective
[...] Read more.
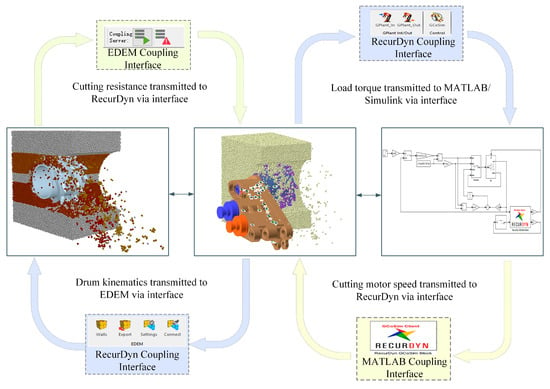
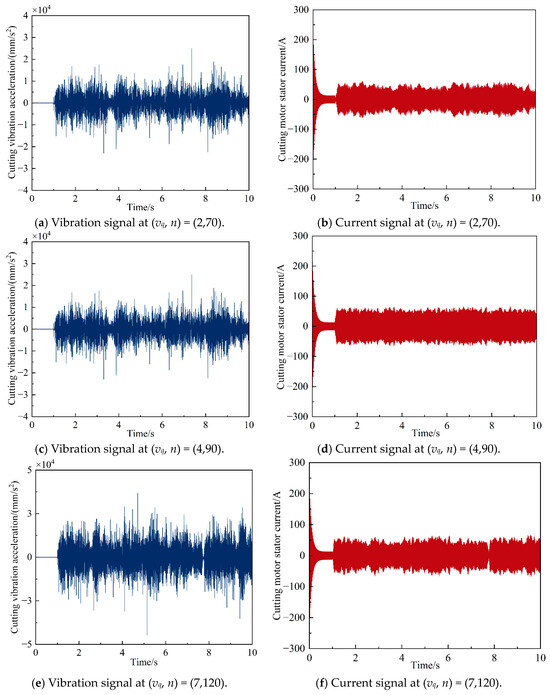
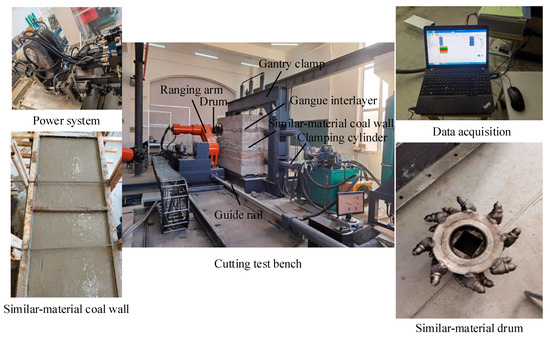
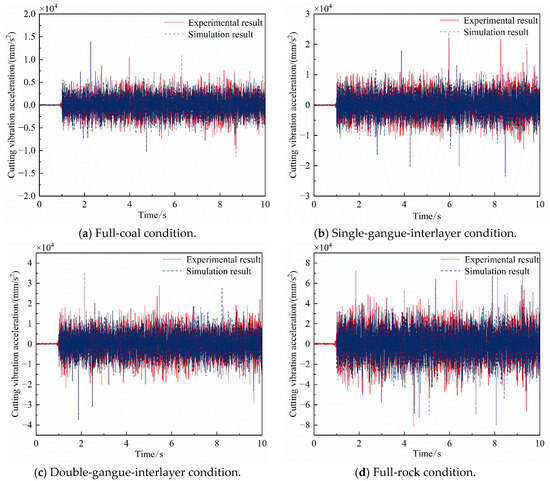
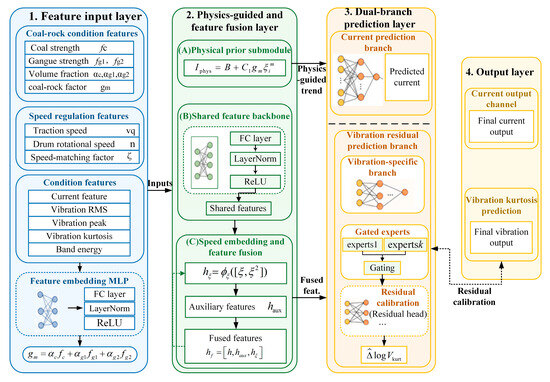
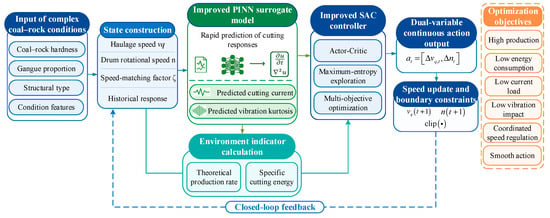
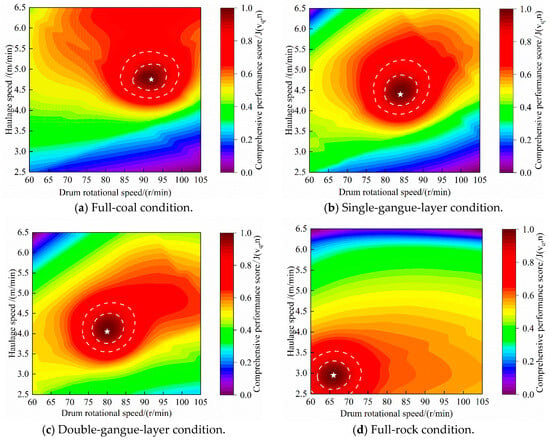
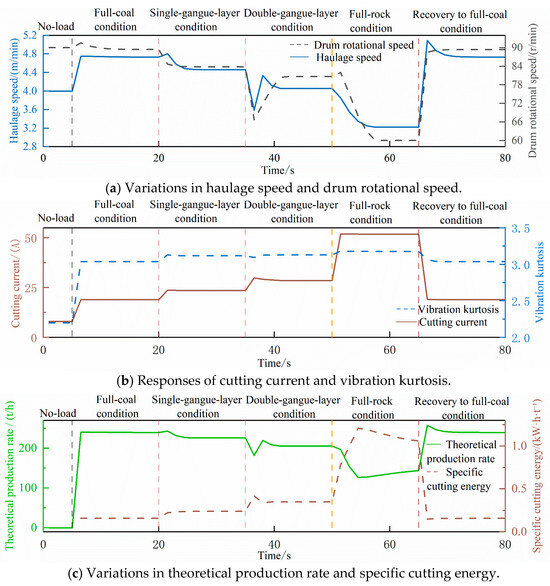
Advanced manufacturing and cutting machinery often operate under variable material properties and uncertain load conditions, making real-time process optimization difficult when high-fidelity simulations and physical experiments are costly. To address this problem, this study proposes a physics-guided surrogate-assisted reinforcement learning framework for multi-objective speed regulation of coal–rock cutting machinery. The haulage speed and drum rotational speed are jointly optimized to balance production rate, cutting specific energy consumption, current load, vibration impact, and speed-regulation stability. First, an EDEM–RecurDyn–Simulink co-simulation model was established to obtain cutting current and vibration response data under different coal–rock structures and speed combinations. Similar-material cutting experiments were conducted to validate the vibration response, with root mean square (RMS) relative errors of 3.38%, 4.21%, 5.75%, and 5.03% under full-coal, single-gangue-layer, double-gangue-layer, and full-rock conditions, respectively. Based on these data, an improved physics-informed neural network (PINN) surrogate model was developed by embedding an equivalent coal–rock difficulty factor, a speed-matching factor, a semi-empirical current prior, and a vibration residual calibration mechanism. The surrogate model achieved R2 values of 0.9623 and 0.9147 for cutting current and vibration kurtosis, respectively. It was then integrated into a Soft Actor–Critic (SAC) control environment to learn continuous dual-variable speed-regulation policies. Across five independent SAC training seeds, the improved SAC achieved an average theoretical productivity of 207.8033 ± 6.5641 t·h−1 and a cutting specific energy consumption of 0.3387 ± 0.0114 kW·h·t−1. Compared with the fixed-speed, empirical speed-regulation, and conventional SAC strategies, the proposed method increased the average theoretical productivity by 2.65%, 5.01%, and 1.77%, respectively, while reducing the corresponding specific cutting energy consumption by 1.37%, 4.05%, and 2.22%. These results demonstrate that the proposed framework provides an efficient intelligent optimization method for condition-aware speed regulation in complex industrial cutting processes.
Full article
(This article belongs to the Section Automation and Control Systems)
►▼
Show Figures

Figure 1
Open AccessArticle
A Hybrid CEEMDAN-GRU Framework with Cooperative Denoising for Vibration Trend Prediction of Hydropower Units
by
Yuhong Li, Shuzhe Hao and Yanhe Xu
Machines 2026, 14(9), 1015; https://doi.org/10.3390/machines14091015 - 7 Sep 2026
Abstract
Accurate vibration prediction is critical for condition monitoring and predictive maintenance of hydropower units, yet it remains challenging due to strong noise interference, severe non-stationarity, and multi-scale coupling characteristics of raw vibration signals. This paper proposes a novel hybrid prediction framework that integrates
[...] Read more.
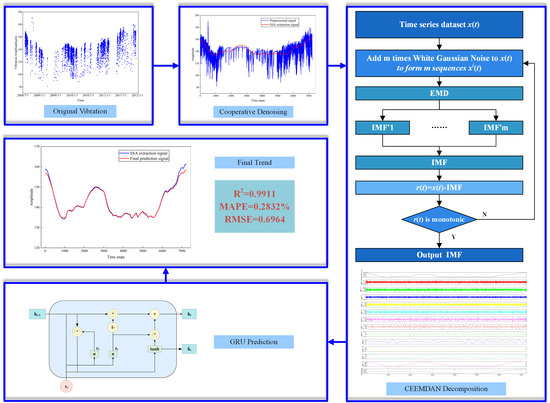
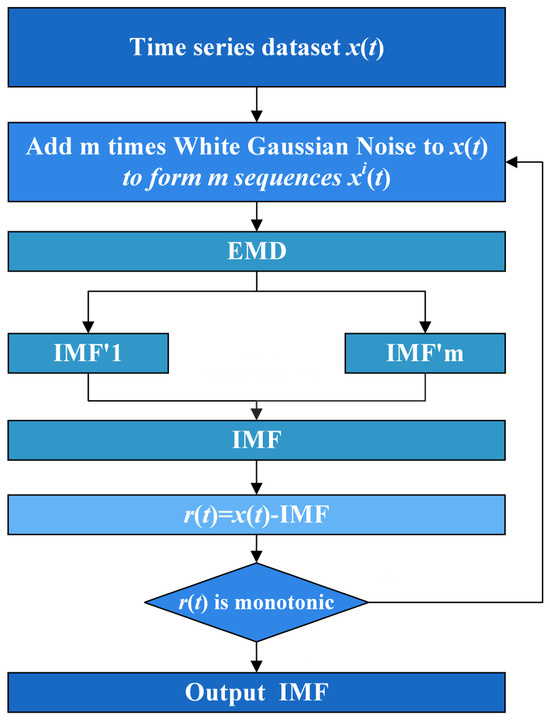
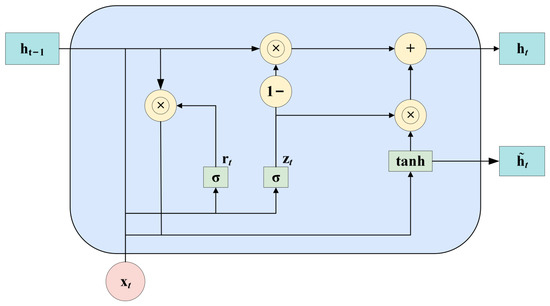
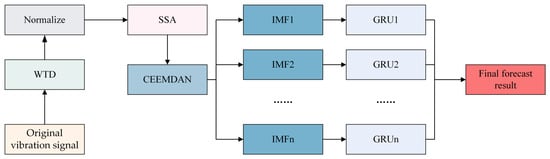
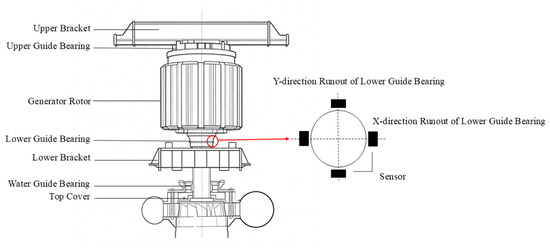
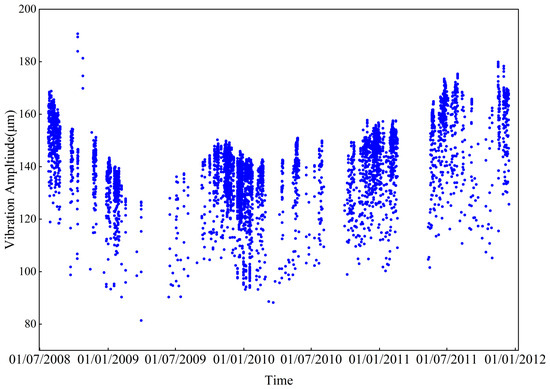
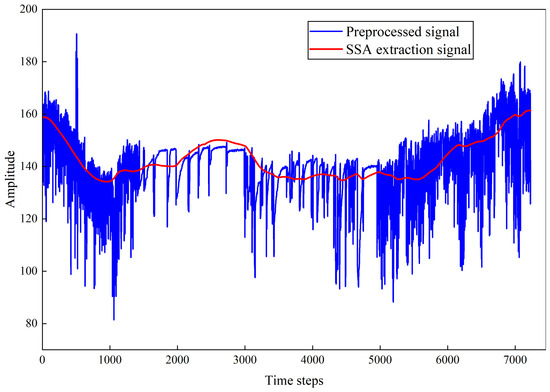
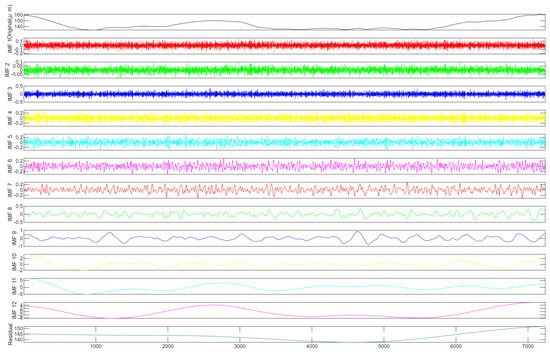
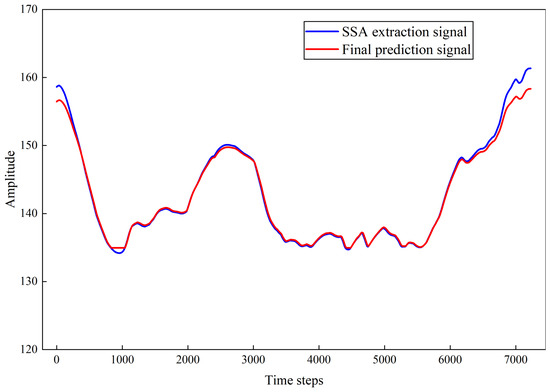
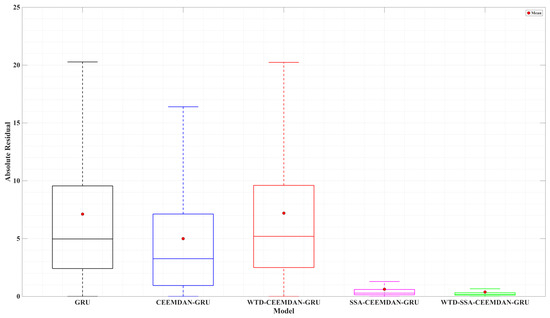
Accurate vibration prediction is critical for condition monitoring and predictive maintenance of hydropower units, yet it remains challenging due to strong noise interference, severe non-stationarity, and multi-scale coupling characteristics of raw vibration signals. This paper proposes a novel hybrid prediction framework that integrates cooperative denoising, multi-scale signal decomposition, and deep learning-based sequential modeling to achieve high-precision long-term vibration forecasting. First, a two-stage cooperative denoising stategy combining wavelet threshold denoising (WTD) and singular spectrum analysis (SSA) is designed to suppress high-frequency noise while effectively preserving the global trend and critical transient features. Then the denoised signal is decomposed into a set of physically interpretable intrinsic mode functions (IMFs) and a residual component via complete ensemble empirical mode decomposition with adaptive noise (CEEMDAN), which alleviates mode mixing and improves decomposition completeness. Subsequently, each IMF component is independently predicted using a gated recurrent unit (GRU) network optimized by the Adam algorithm with adaptive learning rate decay, enabling efficient capture of nonlinear temporal dependencies. The proposed framework is validated using 3.5-year real-world vibration data from an lower guide bearing of a pumped-storage hydropower unit. Experimental results demonstrate that the model achieves MAE = 0.3831, RMSE = 0.6964, MAPE = 0.2832%, and , compared to 0.6666 for the conventional CEEMDAN-GRU model, a 32.45 percentage point increase and a 54% reduction in unexplained variance. Ablation studies and comparative analyses verify the superiority and statistical significance of the cooperative denoising mechanism and the overall hybrid architecture. This work provides a reliable, interpretable, and deployable tool for the condition monitoring and predictive maintenance of hydropower units, supporting proactive operation and reducing unplanned downtime in clean energy systems.
Full article
(This article belongs to the Section Machines Testing and Maintenance)
►▼
Show Figures

Graphical abstract
Open AccessArticle
Exploration of the Inner-to-Outer Diameter Ratio Limit of Field Shaper in Electromagnetic Pulse Tube Forming
by
Qichi Ying, Hao Sun, Yi Lv, Haifan Li, Zhenghao Wei, Junjia Cui and Hao Jiang
Machines 2026, 14(9), 1014; https://doi.org/10.3390/machines14091014 - 7 Sep 2026
Abstract
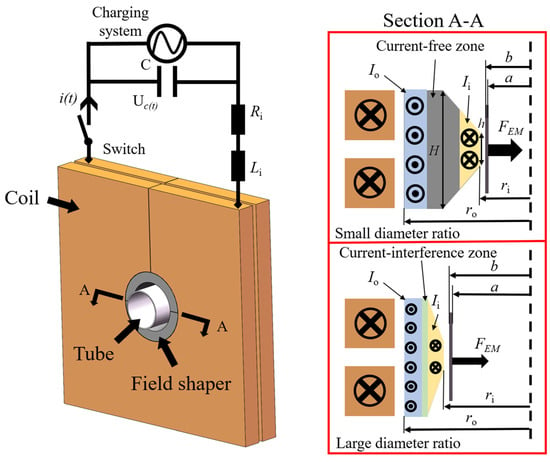
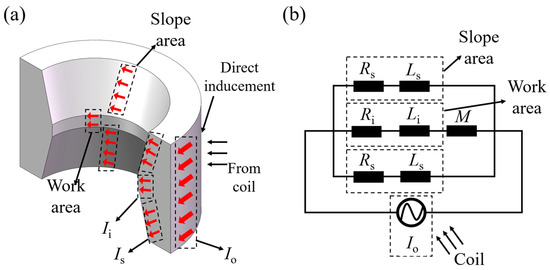
Field shapers concentrate electromagnetic forces on tubes during electromagnetic pulse tube forming and strongly influence deformation capability. This study investigates how the field shaper’s inner-to-outer diameter ratio limits tube compression. A Kirchhoff-law-based analytical model was combined with coupled electromagnetic-mechanical simulations and experiments. The
[...] Read more.
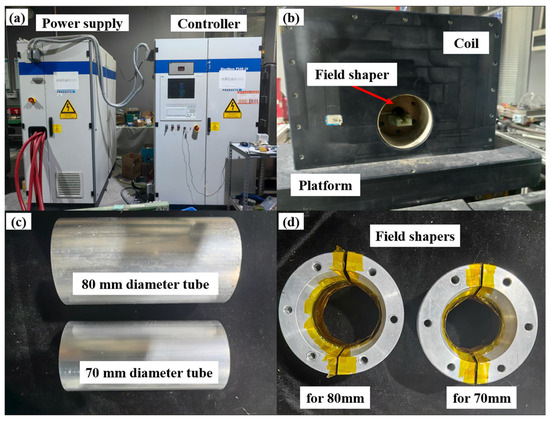
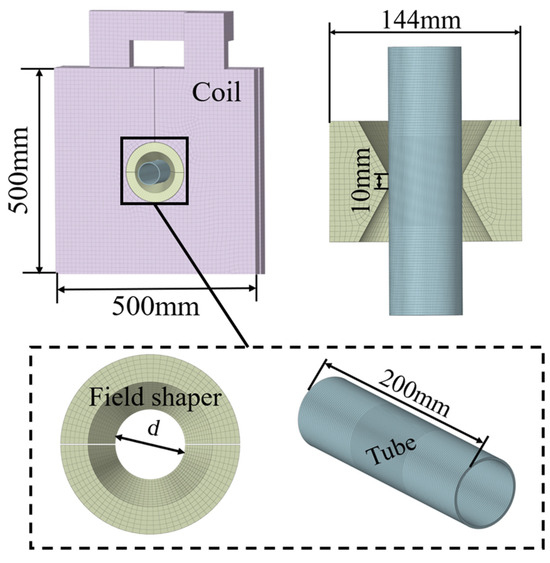
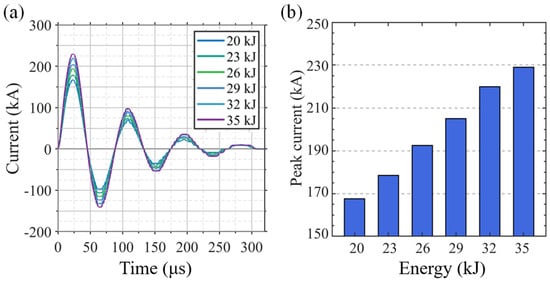
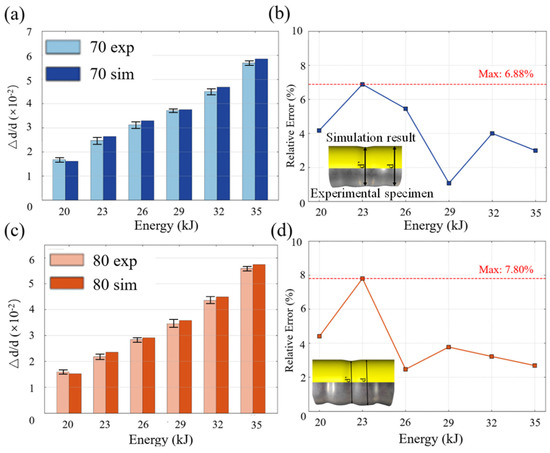
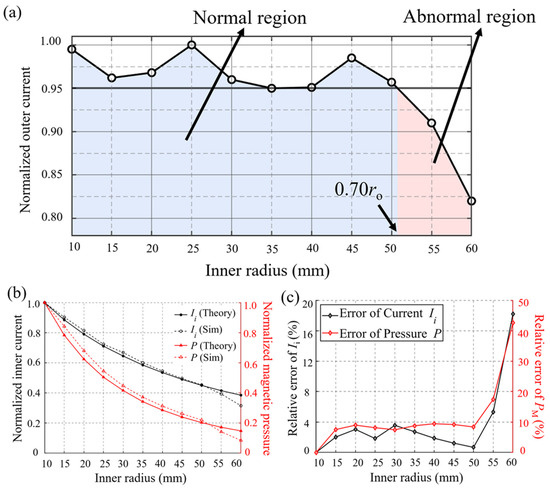
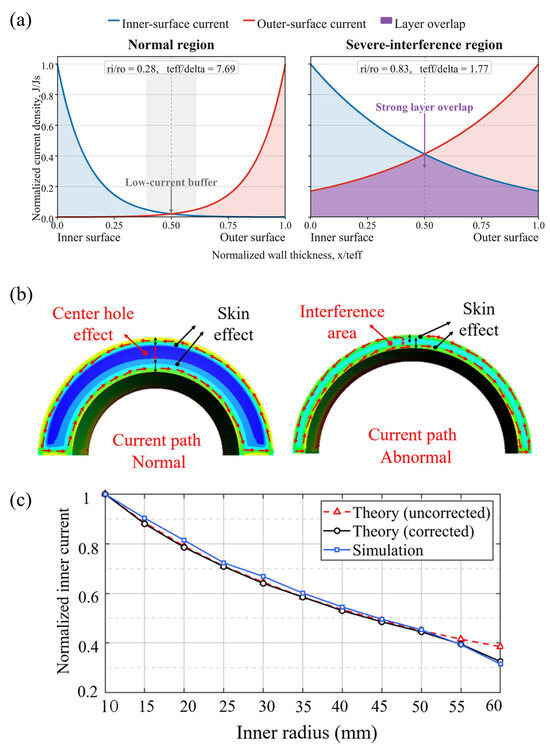
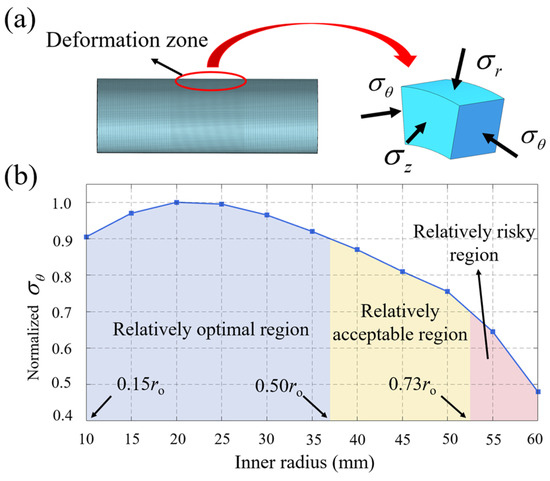
Field shapers concentrate electromagnetic forces on tubes during electromagnetic pulse tube forming and strongly influence deformation capability. This study investigates how the field shaper’s inner-to-outer diameter ratio limits tube compression. A Kirchhoff-law-based analytical model was combined with coupled electromagnetic-mechanical simulations and experiments. The model predicts that increasing the inner diameter reduces both inner-surface current and magnetic pressure. Meanwhile, the hoop-stress indicator first increases and then decreases because the tube radius and pressure exert competing effects. Under the investigated geometry and operating conditions, the favorable inner-to-outer diameter ratio ranges from 0.15 to 0.50. Under these conditions, current-path interference begins near 0.7 and becomes severe above 0.8, rapidly reducing inner-surface current. Experiments using 70 and 80 mm tubes validated the coupled simulation within the investigated range and supported the predicted trend. These findings guide design and indicate that larger tubes require greater field-shaper outer diameters, larger coils, and higher discharge energy.
Full article
(This article belongs to the Special Issue Design and Manufacturing for Lightweight Components and Structures, 2nd Edition)
►▼
Show Figures

Figure 1
Open AccessArticle
DDGF-Net: A Novel Dual-Domain Generative-Discriminative Fusion Network for Gearbox Fault Diagnosis Under Strong Noise Conditions
by
Ruihan Ma, Xuanyue Wang, Jiajun Cheng, Tao Xie, Shuo Li and Chaoge Wang
Machines 2026, 14(9), 1013; https://doi.org/10.3390/machines14091013 - 5 Sep 2026
Abstract
In industrial scenarios, strong background noise can easily overwhelm the weak impulsive signatures of gearbox faults, leading to time-domain waveform distortion and frequency-domain spectral aliasing, which in turn degrades the feature extraction capability of conventional diagnostic models and significantly reduces their diagnostic accuracy
[...] Read more.
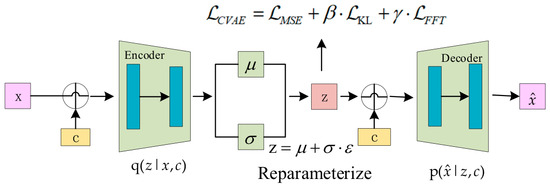
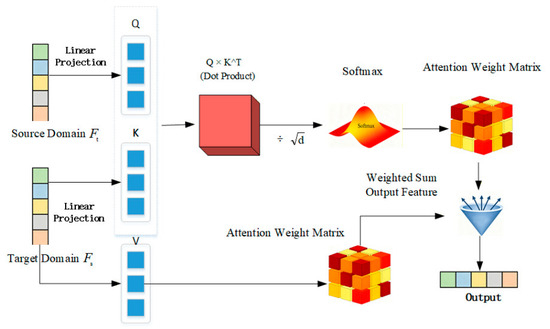
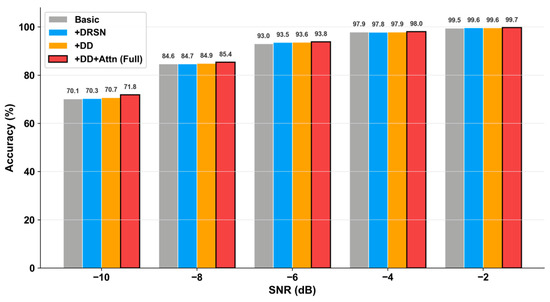
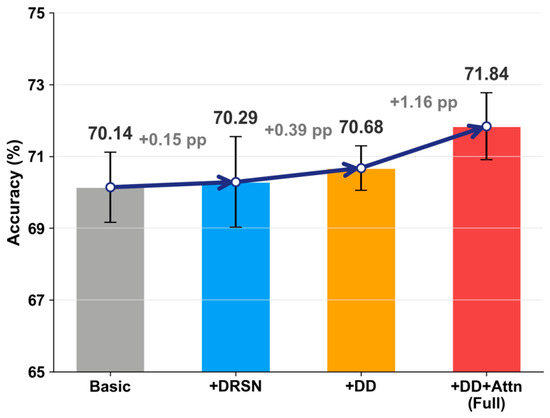
In industrial scenarios, strong background noise can easily overwhelm the weak impulsive signatures of gearbox faults, leading to time-domain waveform distortion and frequency-domain spectral aliasing, which in turn degrades the feature extraction capability of conventional diagnostic models and significantly reduces their diagnostic accuracy and robustness. To overcome this limitation, a dual-domain generative–discriminative fusion network (DDGF-Net) is proposed for robust gearbox fault diagnosis under strong noise interference. The proposed framework consists of three collaborative components. Firstly, an improved conditional variational autoencoder (CVAE) integrating soft-threshold shrinkage and spectral consistency constraints is designed to perform joint time–frequency denoising and signal reconstruction, thereby preserving subtle fault characteristics while effectively suppressing noise. Secondly, parallel time-domain and frequency-domain encoding branches are constructed to extract transient fault impulses and fault characteristic frequencies, respectively, compensating for the inadequacy of single-domain feature representations. Thirdly, a lightweight bidirectional cross-attention mechanism is introduced to overcome the limitations of conventional fixed-weight fusion strategies, enabling dynamic adjustment of the interaction weights between dual-domain features according to the instantaneous noise intensity, thus maximizing the complementary value of cross-domain features. Extensive comparative experiments conducted on the Southeast University(SEU) gearbox dataset demonstrate that DDGF-Net achieves superior diagnostic performance and noise robustness over eight representative methods, particularly under strong noise interference, thereby validating its effectiveness and superiority in harsh diagnostic scenarios.
Full article
(This article belongs to the Special Issue Trustworthy and Intelligent Systems for Machine Health Monitoring and Predictive Maintenance)
►▼
Show Figures

Figure 1
Open AccessArticle
Investigation of Eccentricity Characteristics in a Dual-Stator Single-Rotor Axial Flux Permanent Magnet Synchronous Motor
by
Tao Li, Yuxiu Liang, Ye Yang, Jingyi Tian and Likang Fan
Machines 2026, 14(9), 1012; https://doi.org/10.3390/machines14091012 - 5 Sep 2026
Abstract
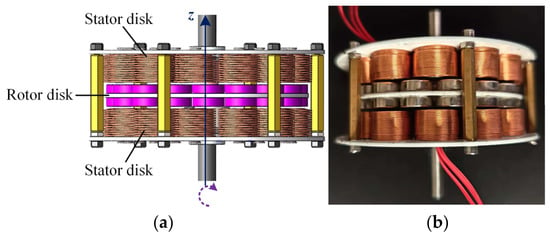
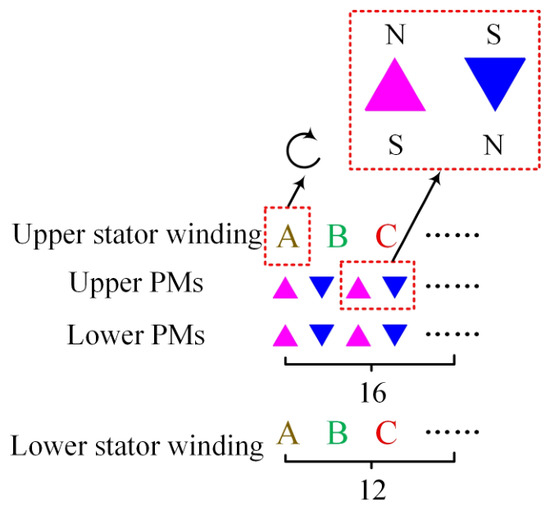
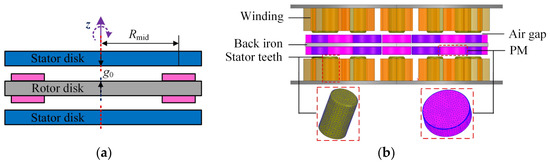
Dual-stator single-rotor (DSSR) axial flux permanent magnet synchronous motors (AFPMSMs) offer high torque density but face reliability challenges due to unbalanced magnetic forces (UMF) and bending moments caused by eccentricity faults. This study investigates the electromagnetic performance of a DSSR AFPMSM under static,
[...] Read more.
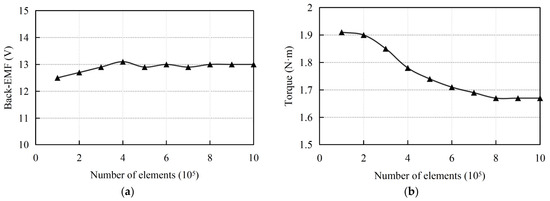
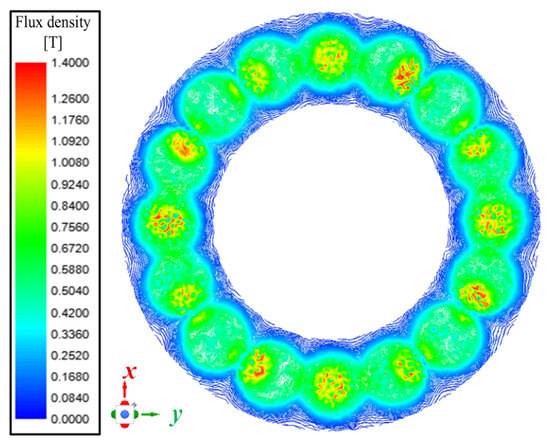
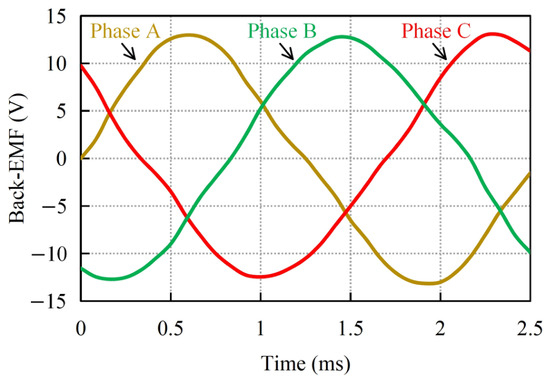
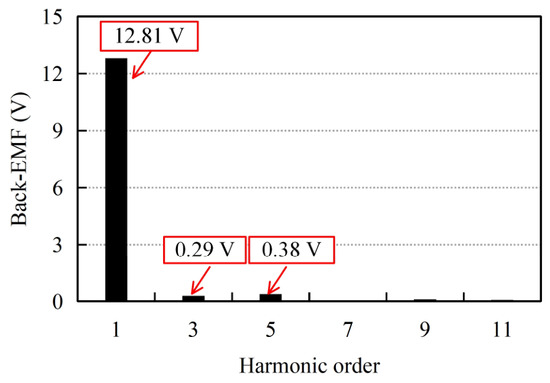
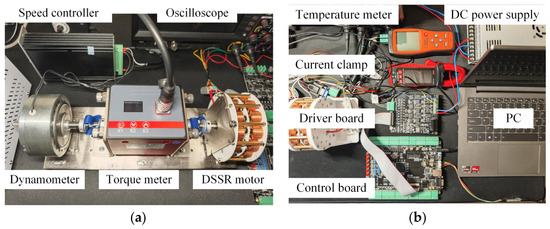
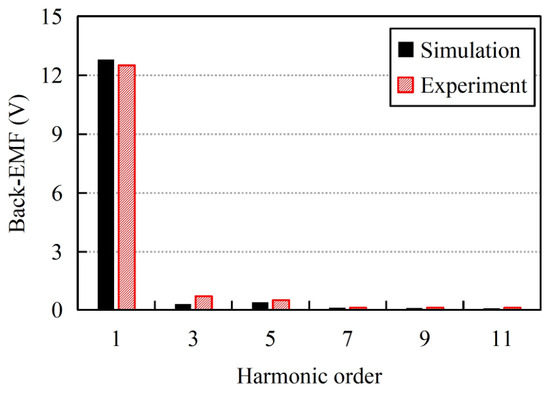
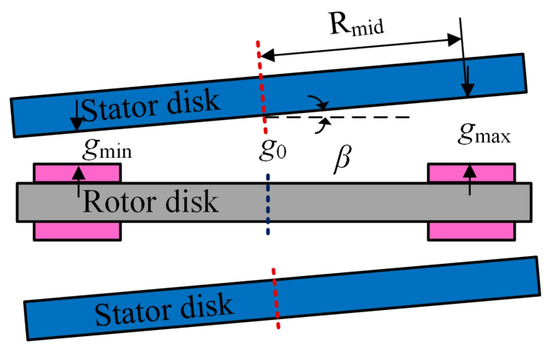
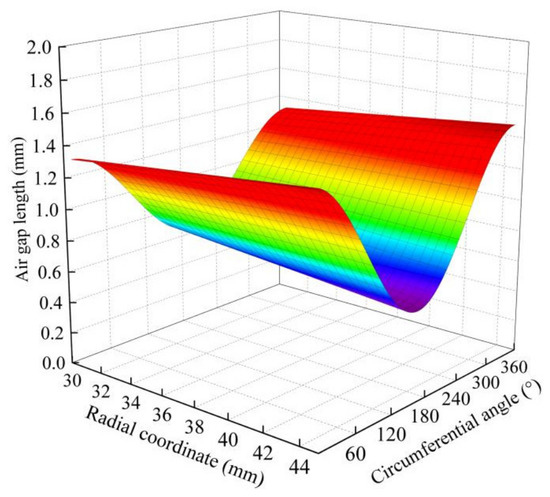
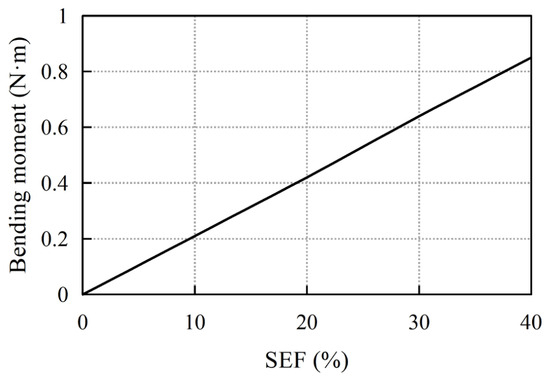
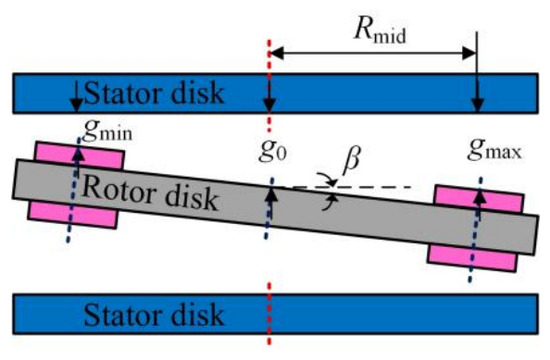
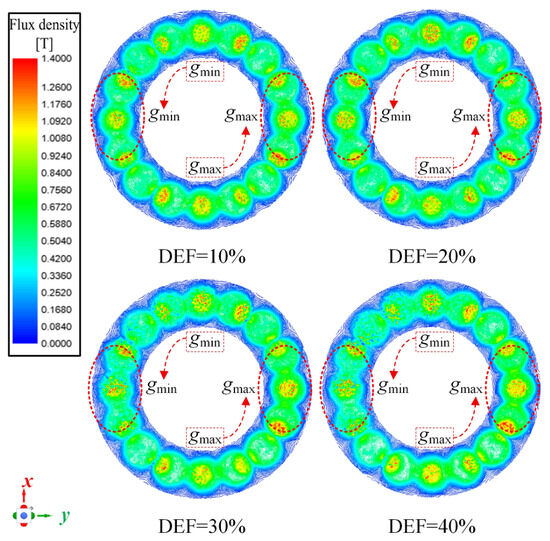
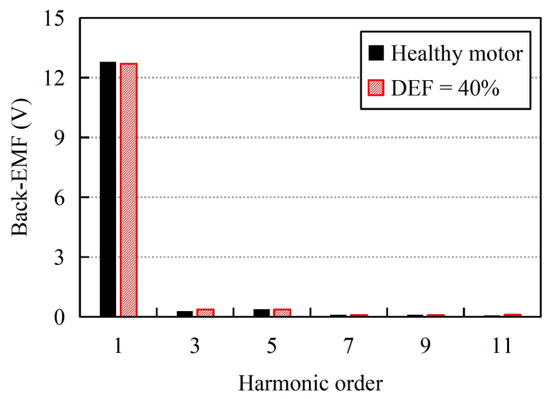
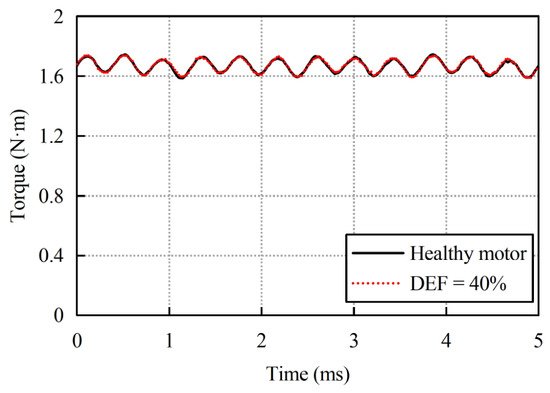
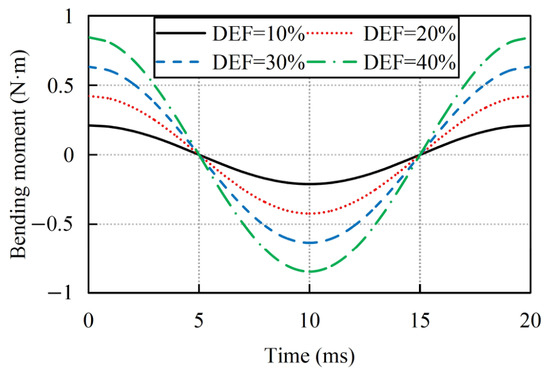
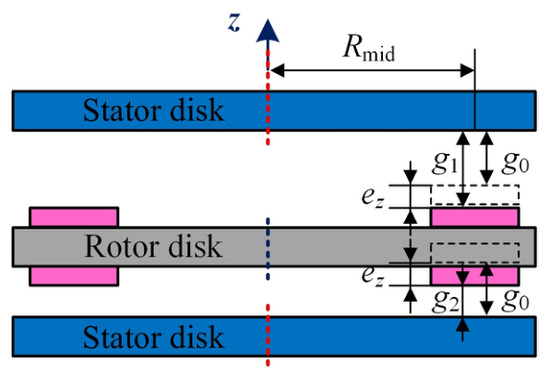
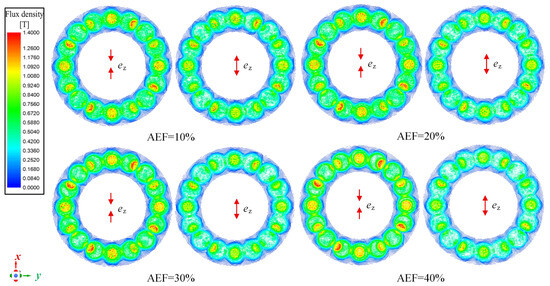
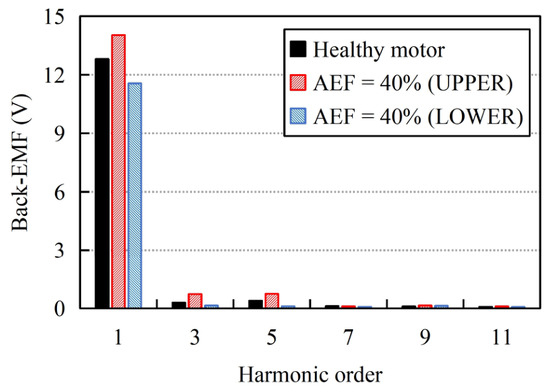
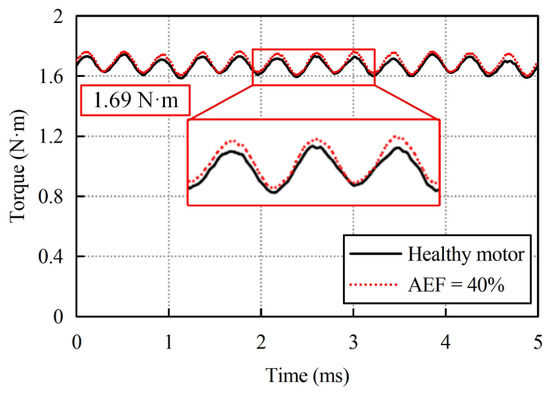
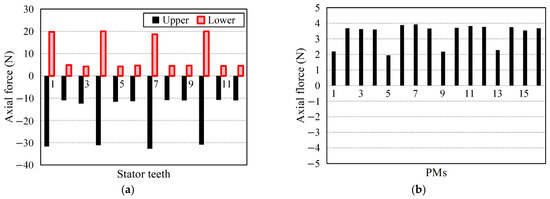
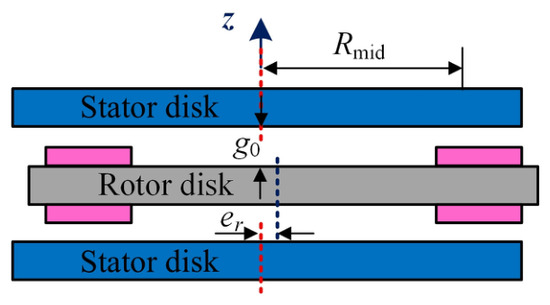
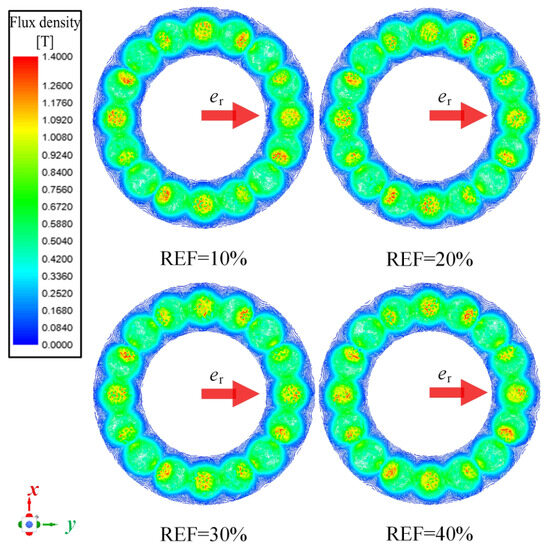
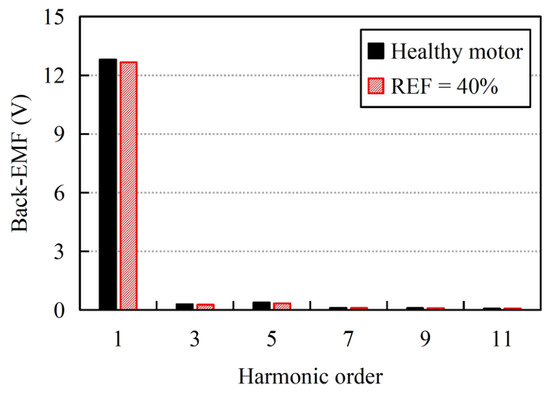
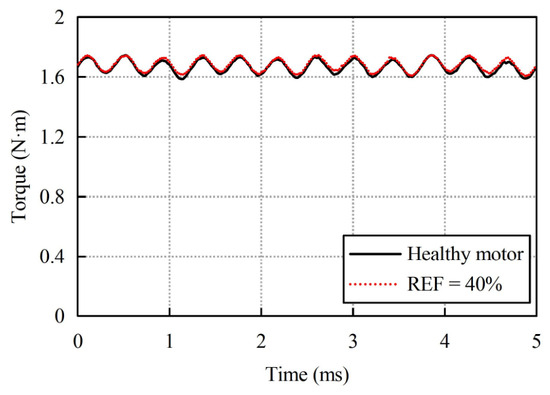
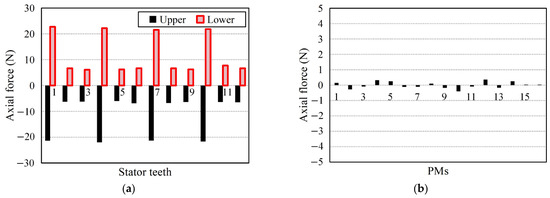
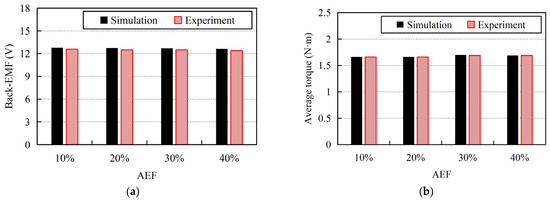
Dual-stator single-rotor (DSSR) axial flux permanent magnet synchronous motors (AFPMSMs) offer high torque density but face reliability challenges due to unbalanced magnetic forces (UMF) and bending moments caused by eccentricity faults. This study investigates the electromagnetic performance of a DSSR AFPMSM under static, dynamic, axial, and radial eccentricities to reveal specific fault signatures and physical mechanisms. The methodology relies on three-dimensional transient finite element analysis (3-D FEA) and is validated by experimental tests on a 500 W prototype. Results indicate that while static and dynamic eccentricities have negligible effects on average torque, they induce significant bending moments where static eccentricity generates a constant moment and dynamic eccentricity produces an alternating one, both proportional to the eccentricity severity. Crucially, axial eccentricity disrupts magnetic symmetry, causing a 17.6% no-load back-EMF imbalance between stators and increasing net axial UMF to 53.2 N at a 40% eccentricity factor. Conversely, radial eccentricity shows minimal impact, confirming the topology’s robustness against radial misalignments. These findings provide essential baseline data for the vibration analysis and condition monitoring of DSSR AFPMSMs.
Full article
(This article belongs to the Section Electrical Machines and Drives)
►▼
Show Figures

Figure 1
Journal Menu
► ▼ Journal Menu-
- Machines Home
- Aims & Scope
- Editorial Board
- Reviewer Board
- Topical Advisory Panel
- Early Career Editorial Board
- Instructions for Authors
- Special Issues
- Topics
- Sections & Collections
- Article Processing Charge
- Indexing & Archiving
- Editor’s Choice Articles
- Most Cited & Viewed
- Journal Statistics
- Journal History
- Journal Awards
- Society Collaborations
- Conferences
- Editorial Office
Journal Browser
► ▼ Journal BrowserHighly Accessed Articles
Latest Books
E-Mail Alert
News
8 September 2026
Meet Us at the 4th International Conference on AI Sensors and Transducers (AIS 2027), 29 July–3 August 2027, Kunming, Yunnan, China
2 September 2026
Meet Us at the 2nd Cross-Domain Intelligent Flight Technology Conference, 18–20 September 2026, Nanjing, China
Topics
Topic in
Electronics, Fluids, Machines, Micromachines, Applied Sciences
Micro-Mechatronic Engineering, 2nd Edition
Topic Editors: Teng Zhou, Antonio F. MiguelDeadline: 31 October 2026
Topic in
Applied Sciences, Electronics, J. Imaging, JMSE, Machines, Robotics, Sensors, Drones
Applications and Development of Underwater Robotics and Underwater Vision Technology, 2nd Edition
Topic Editors: Jingchun Zhou, Wenqi Ren, Qiuping Jiang, Yan-Tsung PengDeadline: 30 November 2026
Topic in
Alloys, Metals, Machines, Applied Sciences
Welding Experiment and Simulation
Topic Editors: Yuewei Ai, Jiangwei LiuDeadline: 31 December 2026
Topic in
Actuators, Automation, Electronics, Machines, Robotics, Eng, Technologies
New Trends in Robotics: Automation and Autonomous Systems
Topic Editors: Maki Habib, Fusaomi NagataDeadline: 31 January 2027
Conferences
Special Issues
Special Issue in
Machines
Digital Twin-Driven Machine Performance and Reliability: Replication, Prediction and Front Running Simulation
Guest Editor: Michael GrievesDeadline: 30 September 2026
Special Issue in
Machines
Advanced Estimation, Control, and Optimization Techniques for Synchronous Machines in Next-Generation Electrified Systems
Guest Editors: Peter Azer, Ahmed AbdelrahmanDeadline: 30 September 2026
Special Issue in
Machines
Advanced Manufacturing Technologies for Improving Fatigue Behavior of Metal Components
Guest Editors: Galya Velikova Duncheva, Jordan Todorov MaximovDeadline: 30 September 2026
Special Issue in
Machines
Advanced Control Techniques for Power Electronics in Modern Energy Systems
Guest Editors: Moria Sassonker Elkayam, Dmitri VinnikovDeadline: 30 September 2026
Topical Collections
Topical Collection in
Machines
Machines, Mechanisms and Robots: Theory and Applications
Collection Editor: Raffaele Di Gregorio