


Abstract
Industrial environments increasingly demand solutions that enable safe, remote and collaborative interaction with physical processes, especially as production systems become more automated, interconnected, and geographically distributed. While digital twins have contributed significantly to monitoring and analysis tasks, they typically lack the immersive, multi-user and interactive capabilities required for advanced supervision and control scenarios. This paper proposes a comprehensive methodology for designing industrial metaverses that extend the concept of digital twins by enabling real-time bidirectional communication with physical automation systems while preserving industrial safety and cybersecurity requirements. The framework integrates a layered communication architecture, a secure command-validation gateway, and an immersive multi-user virtual environment capable of replicating and interacting with a real production process. The methodology is demonstrated through a full case study involving a pick-and-place cell connected to a real Programmable Logic Controller (PLC) via Open Platform Communications Unified Architecture (OPC UA), where a digital twin replaces the physical machine while maintaining identical communication, control logic and safety constraints. The results validate the feasibility of the approach and highlight its potential for remote supervision, operator training, collaborative interaction and experimentation without compromising plant integrity.
1. Introduction
The rapid evolution of digital technologies and the growing adoption of Industry 4.0 principles have transformed industrial production into a data-driven and highly interconnected ecosystem characterized by automation, intelligence, and adaptability. In this context, the concept of the Digital Twin (DT) which is a virtual replica of a physical asset, process, or system, has become central to enabling real-time monitoring, simulation, and optimization in manufacturing environments [1,2]. DT provide unprecedented visibility into industrial operations; however, their applications have traditionally focused on analytics and visualization rather than direct interaction and control.
Despite the considerable progress made through DTs, industries still face challenges when bridging the virtual and physical domains. Most existing implementations operate as observation or decision-support tools, lacking the immersive and bidirectional capabilities required for human-in-the-loop supervision, training, and collaborative control. These limitations have underscored the strategic need for remote and secure interaction mechanisms capable of maintaining operational continuity even when on-site access is constrained, an aspect highlighted during global disruptions such as the COVID-19 pandemic and equally relevant to distributed production, maintenance, and workforce mobility scenarios.
To address these challenges, the concept of the industrial metaverse has emerged as a new paradigm that extends the capabilities of DTs by incorporating real-time connectivity, immersive visualization, and multi-user collaboration [3,4]. Industrial metaverses integrate virtual environments with live industrial data, allowing users to interact intuitively with digital representations of machines and processes. By coupling extended reality (XR) technologies with industrial communication standards such as OPC UA or MQTT, these systems enable synchronized monitoring, control, and training within a unified cyber–physical space. As such, industrial metaverses represent a step forward toward more transparent, resilient, and human-centric production systems.
Recent research has demonstrated the potential of industrial metaverses to enhance decision-making, safety, and operational efficiency. Authors in [3] explored the integration of augmented and virtual reality with DTs to improve remote collaboration and situational awareness in smart factories. In [5], a framework was proposed for real-time synchronization between physical systems and their virtual counterparts, enabling seamless interaction and control. Beyond visualization, studies such as [6,7] have applied metaverse principles to predictive maintenance and workforce training, showing reductions in downtime and improvements in safety. These works collectively emphasize that immersive and collaborative digital environments can become key enablers of next-generation industrial operations.
Furthermore, the integration of industrial metaverses with real-time data and artificial intelligence introduces opportunities for adaptive, self-optimizing manufacturing systems. By merging DTs, IIoT, and XR interfaces, industrial metaverses facilitate predictive diagnostics, anomaly detection, and remote supervision under safe and auditable communication protocols. The present study builds upon this foundation by proposing a complete methodology that enables not only real-time observation but also secure, validated control of physical automation systems through immersive multi-user environments.
1.1. Motivation
Industrial production is increasingly distributed, automated, and dependent on secure remote access. As processes scale across multiple sites and operators, the ability to supervise and control assets without direct physical presence becomes critical. Traditional DTs provide analytical insights but rarely offer the immediacy and responsiveness required for operational decision-making. This gap has motivated the development of industrial metaverses, which are virtual extensions of the factory floor that allow humans and machines to interact in real time through immersive and secure interfaces.
Industrial metaverses enable operators to monitor, command, and maintain physical systems remotely while maintaining strict safety and cybersecurity standards [4,8]. Their integration with industrial communication protocols ensures that each user action is validated before reaching the control logic of the plant, preventing unsafe or unauthorized operations. Moreover, these environments open new possibilities for predictive maintenance, collaborative diagnostics, and operator training, providing a resilient response not only to exceptional global events but also to the continuous evolution of modern manufacturing toward flexible and geographically distributed ecosystems.
While leading industrial automation vendors such as Siemens [9], Rockwell Automation [10], and Dassault Systèmes (DELMIA) [11] already offer advanced DT solutions and industrial software ecosystems, these commercial platforms predominantly focus on analytics, visualization, offline simulation, or virtual commissioning. They rarely provide fully immersive, multi-user environments capable of real-time interaction with physical automation systems, nor do they incorporate safety-validated bidirectional control or low-latency synchronization as part of their operational models. Recent market analyses further indicate that, despite rapid growth in industrial automation technologies, existing off-the-shelf solutions still exhibit limitations regarding responsiveness, collaborative operation, and secure command propagation under heterogeneous, distributed deployment conditions [12]. These gaps highlight the need for research-oriented architectures that extend beyond monitoring and simulation toward active, safe, and synchronous interaction with real automation systems.
In industrial settings, the value of an industrial metaverse is ultimately determined by its ability to support concrete operational workflows under real constraints related to safety, cybersecurity, accountability, and response time [13]. Typical high-impact scenarios include remote supervision and assisted operation by distributed teams [10,14], collaborative troubleshooting and incident response with external experts [14], operator training and rehearsal on a synchronized digital counterpart [15], and factory acceptance testing or change validation prior to deployment [16]. In all these cases, visualization alone is insufficient: the system must enable controlled interaction with the automation layer in a manner that is auditable, role-based, and compatible with established industrial network segmentation practices [17].
From a stakeholder perspective, these scenarios involve plant operators, maintenance personnel, automation engineers, and external service providers, each with different responsibilities and access privileges. Their common requirements include safe command propagation with explicit authorization [17,18], protection of OT networks through a DMZ-based mediation model [17], deterministic and low-jitter synchronization to ensure a coherent user experience [19,20], and interoperability with standard industrial communication protocols [21,22]. These requirements are not fully addressed by existing commercial or research solutions that primarily emphasize simulation, analytics, or offline commissioning.
From a practical standpoint, this implies a clear separation between the types of actions that can be executed remotely through the industrial metaverse and those that must remain local to the physical installation [23,24]. Supervisory and high-level operational actions, such as machine start and stop commands, operating mode selection, reset procedures, alarm acknowledgment, and the observation of real-time process variables [24,25], can be safely issued from within the metaverse when they are routed through validated and authenticated control interfaces [25]. By contrast, safety-critical interventions that require physical confirmation [26,27], including emergency stop recovery [26], hardware-based safety resets [26,27], or maintenance actions that expose operators to mechanical or electrical hazards [28], are deliberately restricted to the real field, even though their state can be monitored remotely. Likewise, low-level commissioning tasks, mechanical adjustments, sensor calibration, and hardware maintenance inherently require physical presence and fall outside the control scope of the metaverse [24,28,29].
From an industrial perspective, the interest in enabling controlled interaction with real systems from within immersive environments is increasingly driven by practical constraints rather than technological novelty [23,24]. Industrial stakeholders consistently seek solutions that reduce dependency on on-site presence [24,30], facilitate access to scarce expert knowledge [30], and support collaborative decision-making across geographically distributed facilities [30,31]. In this context, the ability to supervise processes, execute validated supervisory actions, and observe system behavior remotely is viewed as a means to improve operational continuity [23,24,31], reduce downtime, and accelerate response to incidents or process deviations [32]. Importantly, this demand does not imply unrestricted remote control, but rather the availability of secure, auditable, and responsibility-aware interaction mechanisms that complement existing control-room practices while respecting established safety and organizational boundaries [25,33].
Accordingly, the motivation of this work is to provide a practical and reusable architecture that enables multi-user XR interaction while ensuring that every user action follows an authenticated, validated, and safety-constrained path toward the PLC, thereby supporting real operational use rather than purely observational or exploratory scenarios.
1.2. Related Work
The concept of DTs has been extensively studied in the context of Industry 4.0, with researchers emphasizing their role in enabling real-time monitoring, simulation, and optimization of industrial processes. Authors in [1] provided a comprehensive review of DT technologies, highlighting their applications in manufacturing and predictive maintenance. Similarly, authors in [2] introduced the foundational principles of DTs, describing them as virtual replicas of physical systems that facilitate simulation and analysis. While these works laid the groundwork for DT adoption, they primarily focused on data visualization and predictive analytics, leaving a gap in terms of interactive and immersive capabilities.
Recent research has expanded this paradigm toward what is now referred to as the industrial metaverse, an evolution of DT systems that integrates extended reality (XR), the Industrial Internet of Things (IIoT), and real-time synchronization between the physical and virtual realms. Authors in [34] emphasized the pivotal role of DTs in constructing industrial metaverse architectures, demonstrating how DTs, combined with cloud rendering, virtual-real interaction, and big data visualization, enable intelligent manufacturing and real-time process optimization. Similarly, authors in [8] proposed the IMverse model, a conceptual framework for industrial metaverses in smart manufacturing, characterized by hyper spatiotemporal collaboration, AI-generated content (AIGC) modeling, and human-in-the-loop interaction, underscoring the paradigm shift from automation to immersive and human-centric production systems.
The integration of augmented reality (AR) and virtual reality (VR) into industrial environments has been recognized as a key enabler of immersive and collaborative operations. Authors in [3] demonstrated the efficacy of AR/VR technologies in enhancing remote collaboration and decision-making in smart factories, while authors in [35] investigated their use in workforce training and process simulation. Extending these ideas, authors in [36] introduced the concept of the Meta-Operator within Industry 5.0, illustrating how human-centric extended reality, opportunistic edge computing, and IIoT enable real-time interaction between humans and cyber-physical assets in the industrial metaverse. Their framework bridges Industry 4.0 automation with Industry 5.0 resilience and human well-being.
Parallel developments have focused on the architecture and technical foundations of industrial metaverses. Authors in [37] proposed a data-centric and semantic-enhanced architecture that bridges physical factories and virtual landscapes through the integration of DTs, semantic models, and extended reality. Authors in [38] examined the use of blockchain-based non-fungible tokens (NFTs) for DTs, enabling traceable and secure asset management within industrial metaverse ecosystems. Likewise, authors in [39] analyzed IIoT business models in the age of the industrial metaverse, identifying data-driven and platform-based archetypes that capture value through networked digital ecosystems.
The industrial metaverse has also been recognized as a transformative driver of human–robot collaboration [40,41]. Authors in [42] developed an XR-based assembly system integrating blockchain, edge computing, and DTs to enable real-time perception, decision-making, and control in collaborative manufacturing. Complementarily, authors in [43] present a forward-looking perspective on proactive human-robot collaboration (HRC) in the industrial metaverse, arguing that the integration of digital twins, extended reality, and embodied AI can enable more anticipatory, ergonomic, and human-centric human–machine cooperation in smart manufacturing environments. These developments converge on the notion that the metaverse extends beyond visualization to support real-time interactive control, safety, and adaptive learning in human–robot ecosystems.
Moreover, the convergence of generative artificial intelligence (AI) and immersive DTs has been explored as a foundation for cognitive industrial systems. Authors in [7] demonstrated how cognitive DTs, generative AI, and Internet of Robotic Things (IoRT) technologies facilitate autonomous manufacturing, real-time perception, and deep learning–based decision-making within immersive metaverse environments. Authors in [44] further advanced this view, examining the integration of generative AI and blockchain in enterprise DT metaverses, thereby highlighting AI-driven predictive analytics, workforce optimization, and decentralized data governance.
In addition, the communication and networking requirements of the industrial metaverse have received considerable attention. Authors in [45] investigated ultra-reliable low-latency communication (URLLC) mechanisms in 6G-enabled IIoT environments, identifying the need for short-packet optimization to support the stringent latency, reliability, and Age of Information requirements essential for immersive real-time interactions. These findings are critical for achieving the responsiveness and synchronization necessary for DT-driven metaverse operations.
From a socio-technical and managerial perspective, the industrial metaverse has also been positioned as a transformative force in industrial marketing and business ecosystems. Authors in [46] argued that industrial metaverses virtualize B2B networks, enabling new forms of value co-creation, dynamic strategizing, and stakeholder-centric collaboration. This aligns with the broader understanding of the metaverse as a cyber-physical ecosystem integrating products, people, and processes into shared, data-rich virtual environments.
Case studies and applied research demonstrate that industrial metaverses are transitioning from conceptual exploration to implementation. Studies such as [7,47] have applied industrial metaverse frameworks to predictive maintenance, training, and remote operations, validating their capacity to reduce downtime, enhance safety, and improve decision-making. However, challenges remain in scalability, interoperability, and cybersecurity, as noted by authors in [48] and authors in [4], emphasizing the necessity for standardized architectures, open communication protocols, and trust-based data exchange mechanisms such as OPC UA.
In parallel to academic research and socio-technical analyses, the concept of the industrial metaverse has also been actively shaped by major industrial automation and technology providers. It is commonly framed as a persistent digital environment in which real assets, factories, and systems are mirrored through digital twins to support collaboration, simulation, and continuous improvement across the industrial lifecycle [21].
In this vision, Siemens describes the industrial metaverse as a digital world that mirrors and simulates real machines and factories, enabling interaction with digital twins and continuous scenario evaluation [21]. In a complementary direction, NVIDIA emphasizes industrial facility digital twins as platforms to design, simulate, operate, and optimize industrial assets and processes in virtual environments [49], with a strong focus on scalable simulation and AI-enabled workflows [50]. Rockwell Automation, through Emulate3D, highlights factory-scale digital twin applications such as virtual commissioning and controls testing, aiming to reduce deployment risk and accelerate automation projects [16].
While these commercial visions and platforms offer extensive capabilities for simulation, commissioning, and visualization, they predominantly target offline or semi-offline workflows and decision-support activities [51]. Consequently, the challenge of enabling immersive, multi-user interaction with real PLC-controlled systems under strict cybersecurity and safety constraints remains only partially addressed [52,53], leaving an operational gap between visualization-oriented digital twins and validated, real-time process control [51].
Despite the significant progress made, recent advances have expanded the scope of industrial metaverse research from data-driven DTs toward immersive, AI-enabled, and human-centric cyber-physical ecosystems. However, most current implementations remain largely confined to monitoring, visualization, and predictive analytics. Despite significant progress in integrating DTs with extended reality, IIoT, and edge computing, the ability to perform direct, closed-loop control of physical systems within the metaverse is still limited. Existing frameworks typically operate as decision-support or simulation layers, where commands must be externally executed through traditional control interfaces.
This gap underscores the absence of a truly bidirectional architecture capable of enabling real-time interaction, control, and feedback between virtual and physical entities. Achieving such synchronization requires overcoming challenges related to deterministic communication latency, interoperability of industrial protocols (e.g., OPC UA, MQTT, 6G URLLC), and the cybersecure handling of control commands in shared virtual environments. Consequently, current research calls for methodologies that extend beyond observation and predictive modeling toward active process control within the industrial metaverse, where operators can manipulate physical assets directly through their virtual counterparts. The present study addresses this gap by proposing and experimentally validating a framework that enables real-time, bidirectional connectivity between virtual and physical systems using standard industrial communication protocols.
1.3. Objectives and Main Contributions
The main objective of this work is to define and experimentally validate a comprehensive methodology for the development of industrial metaverses that enable safe, real-time interaction with physical automation systems through synchronized DTs. The aim is to formalize and validate a generalizable, reusable architecture suitable for real industrial environments. The proposed approach integrates multi-user immersive environments, validated command execution, and end-to-end communication using standardized industrial protocols.
The specific contributions of the paper are as follows:
- A complete architecture for industrial metaverses integrating a real-time DT, a multi-user immersive interface, and a demilitarized zone (DMZ)-based communication gateway that ensures secure and validated interaction with PLC-controlled processes.
- The implementation of a command-validation layer enforcing authentication, authorization, and rate limiting of user commands, enabling multi-user remote operation under industrial safety constraints.
- A real-time synchronization pipeline achieving low latency, minimal jitter, and temporal stability over extended operation periods.
- The design of a shared industrial metaverse environment supporting persistent virtual objects, collaborative interaction, spatial audio, and intuitive control modalities.
- A case study involving a pick-and-place industrial cell connected to a Siemens PLC via OPC UA, demonstrating the feasibility and robustness of the proposed framework as an instantiation of the proposed architecture, not merely as an isolated prototype.
1.4. Structure of the Paper
The remainder of the paper is organized as follows. Section 2 describes the proposed methodology for developing industrial metaverses, including the architectural framework, integration workflow, implementation of the pick-and-place validation case, and the design of the multi-user metaverse environment. Section 3 presents the results obtained from the technical evaluation and usability study. Section 4 discusses the findings and their implications for industrial applications, and Section 5 concludes the paper and outlines future research directions.
2. Materials and Methods
2.1. Requirements Analysis and Rationale for the Proposed Methodology
The literature reviewed in Section 1.1 and Section 1.2 highlights several unresolved limitations that restrict the applicability of current industrial metaverse and digital-twin solutions to real-time, safety-critical automation systems. Existing approaches typically lack:
- Secure and deterministic bidirectional connectivity with physical controllers;
- Validated command pathways that prevent unsafe or unauthorized actuation;
- Multi-user synchronization mechanisms oriented to operational contexts, not limited to training or visualization;
- Architectural separation between XR clients and OT networks to ensure cybersecure operation;
- Seamless interoperability across heterogeneous industrial devices and communication standards.
Commercial DT/metaverse platforms (e.g., Siemens [9], Rockwell [10], Dassault [11]) also focus primarily on visualization, simulation, or offline commissioning, offering limited support for immersive, multi-user interfaces coupled with real-time validated control. These gaps indicate that an industrial metaverse intended for operational interaction must satisfy a series of requirements:
- R1. Real-time responsiveness: Deterministic latency and low jitter to maintain temporal coherence between virtual scenes and PLC execution.
- R2. Cybersecure bidirectional interaction: All control actions must be authenticated, authorized, and validated before reaching the PLC.
- R3. Multi-user consistency: The system must maintain a coherent shared state while supporting concurrent presence and interaction.
- R4. OT network protection: Remote clients must never access plant subnets directly, requiring DMZ-based mediation and protocol isolation.
- R5. Interoperability: Integration through standardized industrial communication protocols (OPC UA, MQTT) to ensure portability.
- R6. Scalability and maintainability: Modular design that can accommodate increasing system complexity or user load.
These requirements directly motivate the structure and design decisions of the methodology and architecture presented in the subsequent sections.
2.2. Methodological Overview
The proposed methodology follows a sequential workflow that guides the creation of an operational industrial metaverse, beginning with an analysis of the physical system and concluding with its validation under real operating conditions. The overall structure of this workflow is summarized in Figure 1, which illustrates the five phases and their relationships.
Figure 1.
Methodological workflow summarizing the sequential phases required to design, integrate, and validate a fully operational industrial metaverse. The diagram highlights the following: (i) system analysis and requirement definition; (ii) creation of a high-fidelity digital twin; (iii) implementation of the secure communication and validation layers; (iv) assembly of the multi-user metaverse environment; and (v) validation under real communication constraints. Arrows indicate data dependencies and the progressive refinement of virtual and physical integration.
The process starts by identifying the industrial asset to be virtualized and defining its operational boundaries. This includes documenting the workflow, sensing and actuation elements, control logic, safety constraints, and communication requirements. Establishing this foundation ensures a comprehensive understanding of the system before any virtual representation is developed.
Once the physical process has been characterized, a DT is modeled to replicate its geometry, kinematic structure, operational states, and behavior. This virtual counterpart is configured to support real-time synchronization with the physical process, providing the computational basis upon which the metaverse environment is later constructed. Fidelity and responsiveness are treated as core design considerations to maintain consistency between the physical and virtual domains.
Although the core focus of Phase 2 is on geometric accuracy and kinematic correctness because these elements are essential for real-time synchronization with the PLC, additional visual attributes such as textures, materials, and lighting can be incorporated when required. These elements, while not necessary for executing validated control or ensuring deterministic behavior, contribute to visual realism and can improve situational awareness, operator engagement, and training effectiveness in multi-user XR environments.
After the digital representation is established, a communication layer is designed to enable secure, deterministic, and scalable data exchange between the real system and the metaverse. Interoperable industrial standards such as OPC UA or MQTT are typically employed to structure this communication. In addition, because the metaverse operates in a multi-user and network-exposed context, security becomes a central concern. Measures such as firewalls, network segmentation, encrypted channels, and authenticated access are required to ensure that users connecting from external networks cannot compromise the integrity of the industrial installation.
The virtual model is then integrated into a multi-user metaverse in which remote users can coexist, visualize the process in real time, and, when authorized, perform control actions such as starting or stopping the machine or triggering emergency procedures. Interaction mechanisms are designed to synchronize user actions with the behavior of the physical system while respecting all safety constraints and ensuring that no command can circumvent the protections embedded in the industrial control logic.
The workflow concludes with a validation phase that assesses synchronization accuracy, communication latency, operational stability, and overall user experience. Tests cover both monitoring and control scenarios to confirm that the virtual environment reliably reflects the physical process. Security configurations are also examined to verify that multi-user access does not introduce vulnerabilities into the industrial network.
2.3. Architectural Framework
The proposed methodology relies on a four-layer architectural framework that structures all components required to achieve secure, low-latency, and multi-user interaction between the industrial process and its virtual counterpart. The objective is twofold: (i) maintain a clear separation of concerns that scales across heterogeneous plants and vendors, and (ii) enforce defense-in-depth so that remote collaboration never compromises operational safety. Figure 2 depicts the reference deployment, which maps logical layers onto three networked zones (Application, Perimeter/DMZ, and Cell).
Figure 2.
Reference communication and security architecture with layered delimitation. The four functional layers, namely Metaverse Interaction, Data and Services, Communication and Security, and Physical, are mapped onto three network zones (Application, DMZ/Perimeter, and Cell). The diagram shows how telemetry flows unidirectionally from the PLC to the metaverse, while user-originated commands follow a strictly validated and authenticated path through the DMZ gateway. Firewalls (FW1 and FW2) enforce segmentation, and the session server ensures multi-user consistency.
The four layers that compose this architecture operate in close coordination to guarantee functional integrity, scalability, and secure interoperability. The Physical Layer contains the actual industrial assets, including PLCs, sensors, actuators, and embedded safety mechanisms, and acts as the authoritative source of process behavior whose logic and interlocks cannot be overridden by any remote command. Above it, the Data and Services Layer aggregates and contextualizes information from the physical system, hosting data acquisition modules, semantic asset models, and preprocessing logic that organize operational variables into standardized structures such as OPC UA address spaces or MQTT topics. Typically deployed at the edge or within the application zone, this layer provides a controlled interface between operational technology and higher-level digital services while ensuring that data exposure remains strictly read-only. The Communication and Security Layer mediates all data exchanges between the industrial network and the metaverse, enforcing confidentiality, authenticity, and accountability through encryption, mutual authentication, role-based access control, and continuous auditing. Within this layer, a DMZ-based gateway validates every user-originated command using whitelists and rate limits before forwarding it to the PLC, thus ensuring deterministic, cybersecure operation. Finally, the Metaverse Interaction Layer constitutes the immersive multi-user environment that mirrors the physical process in real time. An authoritative session server maintains state consistency and manages presence, replication, and synchronization among users. Telemetry from the plant flows unidirectionally into this layer, while control commands follow the validated path back toward the PLC through the secure communication chain, ensuring that no external client ever accesses plant subnets directly. Together, these four layers form a coherent and modular blueprint capable of supporting immersive industrial applications that demand real-time monitoring, collaborative interaction, and constrained remote control while preserving safety, cybersecurity, and maintainability.
2.4. Integration Workflow and End-to-End Data Flow
Whereas the architectural framework defines the static structure, the integration workflow specifies how data, events, and control commands circulate across layers at runtime. The pipeline comprises three tightly coupled flows: (i) telemetry acquisition from the industrial system, (ii) synchronization and multi-user visualization within the metaverse, and (iii) validated propagation of user actions back to the control layer.
Process-state acquisition starts at the control layer, where the PLC exposes variables, alarms, and sensor readings via industrial protocols (e.g., OPC UA, Modbus-TCP, EtherNet/IP) or through a gateway mapping device tags to standardized information models. A unidirectional (read-only) channel propagates this telemetry toward the Data & Services Layer, ensuring that the metaverse maintains an updated digital representation without opening write paths into the OT network.
Virtual-world synchronization then occurs at the session server, which ingests the streams, updates the DT, animates kinematics, and broadcasts scene replicas to connected users. Multi-user consistency relies on a real-time relay for presence and interaction, while identity services enforce authenticated, authorized access to persistent sessions.
The reverse path, from user to plant, requires strict validation. User actions (start/stop/mode selection/E-stop requests) are interpreted in the Metaverse Interaction Layer and forwarded to the DMZ validation service, which enforces RBAC, whitelists, and rate limits. Only approved requests traverse secure channels toward the PLC, via deterministic writes or OPC UA method calls. Hardware safety and PLC interlocks retain ultimate authority.
Figure 3 summarises the end-to-end workflow.
Figure 3.
End-to-end integration workflow of the industrial metaverse. The diagram illustrates (i) process-state acquisition from the PLC, (ii) real-time digital-twin synchronization and multi-user state replication, and (iii) validated actuation back to the physical controller. Telemetry flows are read-only and unidirectional, whereas user commands traverse the DMZ validation service before reaching the PLC.
2.5. Implementation and Validation Case: Pick-And-Place Industrial Cell
A representative industrial task was selected to validate the methodology: A pick-and-place operation using a Cartesian manipulator interacting with two conveyor lines. This system is common in packaging and material handling and provides a well-understood benchmark for evaluating digital twin synchronization, real-time communication, and constrained remote control. In the setup of this work, the DT replaces the physical cell while interacting with the real PLC through the same OPC UA channels used by the machine. This enables controlled experimentation under realistic conditions without the risks associated with manipulating a physical cell.
Rather than operating the physical cell, the authors of this work implemented a high-fidelity DT in Unity [54] that mirrors the behavior and I/O interface of the real system. This choice provides a safer and more flexible testbed to study the proposed architecture while keeping the entire communication stack and procedures unchanged: identical OPC UA endpoints and addressing, the same command-validation policies, and the same PLC safety interlocks and state machine. As a result, the findings obtained with the DT generalize to the physical deployment without loss of validity, while also improving repeatability, fault injection, and multi-user stress testing under controlled conditions.
The cell consists of a three-axis Cartesian manipulator over two parallel conveyors, see Figure 4 and Figure 5. The primary conveyor transports a mixed flow of cans and boxes in random order, see Figure 5a, while the secondary conveyor evacuates the extracted cans, see Figure 5b. The manipulator spans the full width of the primary line and is powered by industrial servomotors providing repeatable, medium-speed motion suitable for discrete handling. A pneumatic gripper ensures robust grasping of cylindrical cans without vision-based alignment.
Figure 4.
Overview of the digital-twin prototype of the pick-and-place industrial cell. Subfigures show: (a,b) overall system views including conveyors and manipulator; (c) virtual control panel replicated from the physical HMI (English translation to each non-English term that appears: “Process Information” for “Información del Proceso”; “graphs, counters, errors and incidents” for “gráficas, contadores, errores e incidencias’; “Previous” for “Anterior’; and “Next” for “Siguiente’); (d) Cartesian manipulator and pneumatic gripper.
Figure 5.
Main components of the digital twin: (a) primary-line conveyors transporting mixed objects; (b) secondary conveyor used for evacuated cans; (c,d) virtual models of boxes and cans used in the production flow.
Sensing is implemented through discrete photoelectric reflex sensors to replicate a common industrial scenario and reduce dependence on machine vision. A sensor at the pick zone detects the presence of a can on the primary conveyor, triggering a stop and initiating the pick sequence. Two downstream sensors count cans and boxes at the end of each conveyor for continuous production monitoring. The controller is a Siemens S7-1200 PLC (from Siemens manufacturer, located in Munich, Germany) orchestrating conveyor logic, robot actuation, pneumatic routines, safety interlocks, and sequencing.
The nominal cycle proceeds as follows: items move along the primary conveyor until a can enters the detection zone; upon detection, the PLC stops the conveyor and commands the manipulator to pick and place the can onto the secondary conveyor; the primary conveyor then resumes while the secondary transports the can to its counter. Boxes remain on the primary line until their counter. The workflow integrates discrete-event logic, motion control, pneumatics, multisensor coordination, and safety-critical execution.
The PLC manages several operating modes, namely IDLE/READY, AUTO, HOLD (normal stop), RESET/Recovery, and E-STOP, which ensure safe transitions between monitoring, execution, controlled stops, and emergency shutdown. Figure 6 illustrates the mode transition model and the internal microcycle in AUTO.
Figure 6.
Algorithmic workflow of the pick-and-place control: AUTO loop, normal stop, emergency interruption, recovery, and production counters.
Recreating this cell as a high-fidelity DT and connecting it to the real PLC via OPC UA allows the metaverse to behave as a functional surrogate of the physical system. All states, events, and actuation commands flow through the same validated paths used in production, providing a robust framework for validating real-time synchronization, multi-user interaction, and secure remote control.
The cell operates under industrial control modes designed for safe, predictable, and recoverable behavior. These modes are implemented in the real PLC and mirrored in the DT to guarantee functional equivalence. The logic governs mode transitions, coordinates conveyors and manipulator, and enforces safety interlocks, Figure 6.
The system starts in IDLE/READY, a safe baseline with the PLC in RUN, actuators in initial positions, and no motion until interlocks are satisfied. When conditions are verified and an authorized START is issued, the controller enters AUTO. In AUTO, the primary conveyor runs until a can is detected at the pick zone; the PLC halts the conveyor, the manipulator performs a synchronized pick-and-place, and then the conveyor resumes. End-of-line sensors increment can and box counters for real-time production tracking.
HOLD provides a controlled stop: if a stop is requested during AUTO, the controller completes any ongoing placement and then halts. Operation can resume without reinitialization. E-STOP immediately de-energizes motion regardless of state; recovery requires a local physical reset and validation of safety inputs. Only then can the system enter RESET/RECOVERY, restore homing, reinitialize subsystems, and return to IDLE/READY. This deterministic strategy mirrors industrial practice and ensures that interactions in the metaverse remain consistent with the real system.
2.6. Industrial Metaverse Environment
The proposed methodology was validated within a multi-user industrial metaverse developed in Unity, see Figure 7. The virtual environment reproduces the DT of the pick-and-place cell and allows multiple remote users to visualize, manipulate, and supervise the process in real time while maintaining continuous synchronization with the physical PLC. The underlying networking architecture enables shared presence, low-latency communication, and coordinated interaction among all connected participants.
Figure 7.
Multi-user industrial metaverse used in the case study. (a) Authentication lobby where clients establish secure sessions; (b,c) shared avatars and dynamic object introduction supporting collaborative tasks; (d) validated interaction with machine controls linked to the real PLC; (e) live visualization of process variables.
From a practical standpoint, the 3D assets used in the DT originated directly from the industrial CAD assemblies of the physical pick-and-place cell. Exporting the mechanical models in FBX format preserved hierarchy, pivot placement, and kinematic relationships, ensuring that geometric proportions and motion ranges were faithfully reproduced in Unity. To make the CAD-derived assets suitable for real-time rendering on standalone VR hardware such as Meta Quest 2, several optimization steps were applied: high-resolution geometries were cleaned to remove non-visible internal features, mesh density was reduced while maintaining silhouette accuracy, and materials were consolidated to minimise draw calls. Simplified colliders replaced complex mesh-based collision geometries, and the kinematic hierarchy was reorganized to support animation driven directly by live PLC telemetry. Through this workflow, the virtual model retained both visual fidelity and functional correspondence with the real system while meeting the performance requirements of a multi-user industrial metaverse environment.
In addition to geometric optimization, the visual appearance of the DT models was refined to improve realism while maintaining compatibility with real-time rendering on standalone VR hardware. Original CAD files typically lack texture information, so materials were recreated in Unity using lightweight Physically Based Rendering (PBR) shaders, with albedo, smoothness, and metallic parameters adjusted to replicate the surface finishes of the physical machine. UV maps were simplified or regenerated when necessary to avoid stretching artefacts, and texture resolutions were downsampled to balance visual fidelity with memory constraints. Dynamic elements such as conveyors and actuators were assigned distinct visual cues to enhance immediate recognizability during operation. These enhancements contribute to a more realistic and operationally informative representation of the industrial cell, supporting the overarching goal of bridging virtual and physical realms through high-fidelity yet performant DT.
Before accessing the virtual workspace, users authenticate in a dedicated lobby, see Figure 7a, where they register their credentials and establish a secure connection with the metaverse session server. Once connected, they can join the industrial scenario and interact collaboratively. Although all participants in this study were granted the same level of access, the system natively supports role-based authorization policies, allowing certain users to operate machinery while others are restricted to observation or monitoring functions.
Each participant is represented by an upper-body avatar generated through the Meta Avatar SDK, see Figure 7b,c. This design provides a strong sense of embodiment and social presence while maintaining computational efficiency, a crucial trade-off for collaborative industrial tasks. The system replicates head, hand, and torso movements of all connected users and incorporates spatialized voice communication, ensuring natural interaction and immersion. Ambient sound effects, such as conveyor motion, pneumatic actuation, and robot movement, are integrated to reinforce environmental realism. All user actions on shared virtual elements are synchronized across the session, ensuring that every participant perceives a coherent and consistent scene state.
Within the environment, users can directly interact with the virtual control panel of the machine, see Figure 7d. The Start, Stop, and Reset buttons are linked to the real PLC through the validated communication path described in Section 2, ensuring that every action follows the same safety and authorization mechanisms as in the physical setup. The emergency stop (E-STOP) operates identically, enforcing industrial safety logic at all times. To prevent conflicting operations, an ownership rule is applied whereby only one user can manipulate a shared control element at any given moment. When the element becomes available again, other participants regain access seamlessly.
Beyond the predefined controls, the metaverse also supports the creation of dynamic, persistent objects during collaborative sessions, see Figure 7b,c. Users can introduce three-dimensional models, functional tools, or information panels, which are instantly replicated for all participants and remain accessible throughout the session. This functionality facilitates collective experimentation, documentation, and remote troubleshooting, reflecting the flexibility and adaptability of immersive industrial environments.
Real-time dashboards integrated into the scene display key process variables streamed from the PLC, including production counters, connection status, and temporal trends, see Figure 7e. These indicators update synchronously for all users at the telemetry refresh rate, providing a unified and transparent view of system performance. By maintaining a shared situational awareness, distributed teams can monitor, analyze, and coordinate operations efficiently regardless of physical location.
Navigation within the virtual facility combines fluid locomotion and teleportation to accommodate different comfort preferences. Interaction is optimized for natural hand tracking, though VR controllers can also be used. Physical collision between avatars is intentionally disabled to avoid occlusion or deadlocks in confined spaces and during concurrent manipulation. Together, these interaction mechanisms ensure that the industrial metaverse functions as an intuitive, responsive, and safe environment for collaborative supervision and control.
2.7. Research Design
The evaluation strategy was designed to assess both the technical performance and the user-centered usability of the industrial metaverse prototype. The study combines long-duration operational logging with structured user testing involving non-expert participants, allowing for the proposed methodology to be validated from multiple complementary perspectives. The goal is to determine whether the DT, connected to the real PLC through the same OPC UA communication interfaces used by the physical cell, can provide reliable real-time behavior, stable synchronization, and an interaction experience accessible to operators without prior industrial training.
The technical evaluation focuses on performance indicators commonly used in real-time industrial communication systems. These include the end-to-end latency between PLC outputs and their visualization in the metaverse, the reciprocal latency of user-issued commands, jitter and update-rate variability, the consistency of state synchronization across the DT, and the reliability of the command-validation gateway. These metrics were derived from continuous logs collected during multiple operational cycles and during an extended eight-hour uninterrupted trial. This long-duration experiment was designed to capture system behavior under realistic operating conditions, revealing any potential performance degradation, drift, or intermittent communication issues.
A complementary usability study was conducted with non-expert participants to evaluate how intuitively users could interact with the metaverse interface and whether the remote-control workflow was understandable without prior industrial training. A total of 22 participants volunteered for the study. Their ages ranged from 20 to 45 years, with a mean mean value of 24.7 and a standard deviation (SD) of 8.6. The sample included 13 women and 9 men. Regarding educational background, 16 participants held undergraduate degrees, 5 held postgraduate degrees, and 1 had completed the PhD. None of the participants had previous experience with PLC programming or industrial control systems.
With respect to immersive technologies, 16 participants had never used VR/AR/XR devices, and 6 indicated occasional or frequent prior exposure. This variability allowed the evaluation to capture usability perceptions across a realistic range of familiarity levels with immersive environments.
All participants were instructed to observe the behavior of the virtual pick-and-place cell, trigger control actions through the shared interface, and react to state changes streamed in real time from the physical PLC. At the end of each session, participants completed a short semi-structured interview consisting of three open-ended questions designed to elicit qualitative feedback about their experience:
- 1.
- How would you describe your overall experience interacting with the industrial metaverse environment?
- 2.
- Were there any aspects of the interaction that felt uncomfortable, unintuitive, or technically limiting?
- 3.
- Which elements of the system (e.g., navigation, object manipulation, collaboration, responsiveness) worked particularly well or could be improved?
These questions were intentionally open to allow participants to freely express their impressions while ensuring coverage of core dimensions such as usability, comfort, and perceived system performance.
After completing the tasks, each participant answered the System Usability Scale (SUS) [55], together with a brief post-task interview. This design ensured that both technical performance and human-centered interaction could be evaluated through complementary, structured methods.
2.8. Data Analysis
The analysis procedure was structured to extract quantitative performance indicators from the system logs and to interpret user feedback obtained during the usability evaluation. All data were processed using standard statistical techniques to ensure reproducibility and to allow for direct comparison with metrics commonly reported in studies on DTs, industrial communication, and human–system interaction.
For the technical assessment, raw logs generated during normal operation and during the eight-hour continuous test were segmented into individual execution cycles. Each cycle included can detection, conveyor stop, robot pick-and-place motion, and production counting. Time-stamped entries were used to calculate the end-to-end latency between PLC state changes and their corresponding updates in the metaverse, the reciprocal latency of control commands originating from users in the virtual environment, and the jitter associated with periodic telemetry updates. These indicators were analyzed by computing mean values, standard deviations, confidence intervals, and outlier rates. Temporal drift was evaluated by comparing early-cycle and late-cycle performance to identify long-term degradation or synchronization instability.
Integrity and reliability of the command-validation subsystem were assessed by examining all write attempts recorded in the logs. Each request was classified as authorized, rejected, rate-limited, or invalid according to the security rules defined in the DMZ layer. Error rates and rejection patterns were analyzed to verify compliance with role-based access control constraints and to ensure that no unsafe command or malformed packet reached the industrial controller.
In line with previous research on interaction and usability assessment in virtual and industrial environments [56,57,58,59,60], the evaluation incorporated structured usability tests and short post-task interviews to obtain both quantitative and qualitative evidence about the proposed system. The assessment focused on determining whether non-expert users could interact effectively with the metaverse interface and whether the remote-control workflow was perceived as clear, intuitive, and reliable.
To measure perceived usability, the System Usability Scale (SUS) was administered after each user completed the interaction tasks [55]. The SUS consists of ten statements rated on a five-point Likert scale, see Table 1. Positive items are scored by subtracting one from the selected value, whereas negative items are reverse-scored by subtracting the response from five. The sum of all adjusted item scores is then multiplied by 2.5, producing a final usability score ranging from 0 to 100. This scoring procedure was applied consistently across all participants, and mean values together with standard deviations were computed both at item and global scale levels to observe response variability.
Table 1.
Statements comprising the System Usability Scale (SUS), a standardized 10-item questionnaire used to evaluate perceived usability of interactive systems [55]. Items alternate between positive and negative formulations to assess consistency, ease of use, confidence, and perceived complexity.
The analysis placed particular emphasis on understanding how users with no prior experience in industrial control systems perceived the interface. Their results were compared with those from technically experienced participants to identify potential usability barriers that could emerge during remote operation scenarios. Item-level patterns were inspected to detect tendencies related to perceived complexity, consistency of interface functions, confidence during operation, and expected learning effort.
Qualitative feedback from brief follow-up interviews complemented the quantitative analysis. Comments were categorized to capture recurring themes such as clarity of system feedback, intuitiveness of the control actions, and perceived trust in the communication between the virtual environment and the physical process. This mixed-method approach allowed for the usability findings to be interpreted not only from a numerical perspective but also in terms of user experience and operational understanding.
3. Results
The results obtained from the technical performance evaluation and the user study provide a comprehensive validation of the proposed industrial metaverse architecture. The findings confirm that the DT can accurately reproduce the behavior of the physical pick-and-place cell while maintaining stable real-time connectivity with the PLC through the same interfaces used by the real system.
The version of the developed Industrial Metaverse for validating the approach is shown in a video demonstration (see https://media.upv.es/player/?id=e8681970-bdfc-11f0-869d-e7521f7625bf (accessed on 15 November 2025)), where three users participated to showcase the application. All three utilized the Meta Quest 2 Virtual Reality headset, each in separate spaces, and all of them were previously acquainted with the virtual environment.
Figure 8 illustrates several key moments extracted from the video demonstration of the industrial metaverse prototype, showing how multiple users interact simultaneously with the shared environment while the system remains synchronized with the real PLC. In each subfigure, the upper row displays the perspective of the three connected users as they move, act, and collaborate within the virtual workspace. The lower row shows the real-time LADDER execution of the physical PLC, allowing for the direct observation of how user actions in the metaverse propagate through the validated communication chain described in Section 2.3. This visualization confirms that all interactions respect the real PLC’s safety logic, communication constraints, and execution cycle, even though the physical industrial cell has been replaced by its DT for demonstration purposes. This substitution does not affect generality, since the DT operates through exactly the same interfaces and validation layers as the real machine.
Figure 8.
Key moments from the multi-user video demonstration (see https://media.upv.es/player/?id=e8681970-bdfc-11f0-869d-e7521f7625bf, accessed on 15 November 2025) of the industrial metaverse. Each subfigure shows the real-time interaction of the three connected users within the virtual pick-and-place cell. (a) Remote machine start initiated from the metaverse interface. (b) Long-distance navigation using the teleportation mechanism. (c) Visualization of real-time process data streamed from the PLC. (d,e) Introduction and shared manipulation of persistent virtual objects, immediately replicated for all users.
Figure 8 illustrates several key moments extracted from the video demonstration of the industrial metaverse prototype, showing how multiple users interact simultaneously with the shared environment while the system remains synchronized with the real PLC. Each subfigure displays the perspective of the three connected users as they move, act, and collaborate within the virtual workspace.
In Figure 8a, one participant starts the machine remotely through the shared virtual control panel. Figure 8b highlights the use of the teleportation mechanism, which enables efficient long-distance navigation inside the industrial metaverse. In Figure 8c, the focus shifts to system feedback: users observe real-time process data streamed from the PLC, including counters and state indicators. Figure 8d,e showcase a distinctive feature of the environment: the introduction of persistent shared objects. A participant spawns new 3D items inside the scene, and these objects appear simultaneously for all users. Any participant can grab, move, or manipulate them, and this behavior is replicated across the entire session.
3.1. Technical Performance
The technical evaluation confirmed that the proposed industrial metaverse architecture achieved stable, low-latency performance and reliable synchronization under all test conditions. Time-stamped logs collected during 1200 complete pick-and-place cycles showed that the end-to-end latency between PLC state updates and their visualization in the metaverse remained consistently low, with a mean value of 38.4 ms (SD = 6.1 ms) and individual measurements ranging from 29 ms to 54 ms. Jitter was minimal, with a cycle-to-cycle variability of approximately ±4–6 ms, which ensured smooth temporal alignment and visual coherence in the virtual environment. Figure 9 summarises the temporal behaviour of both latency channels throughout the 8-h test.
Figure 9.
Temporal evolution of end-to-end latency during the 8-h stress test. Telemetry latency (PLC → metaverse) ranged from 29 ms to 54 ms (mean 38.4 ms, SD 6.1 ms), while control-actuation latency (metaverse → PLC) exhibited similar variability (mean 42.7 ms, SD 7.4 ms). Both remained well below the 100 ms perceptual threshold for industrial HMI interactions, with narrow jitter bands and no observable temporal drift.
Reciprocal latency-measured from user interactions in VR to the execution of the corresponding validated command on the PLC-exhibited similar performance, with an average value of 42.7 ms (SD = 7.4 ms). These results indicate that neither the command-validation layer nor the OPC UA communication stack introduced significant delays. Importantly, all latency values remained well below the 100 ms perceptibility threshold typically associated with operator response time in industrial contexts.
Moreover, during the eight-hour uninterrupted stress test, the synchronization pipeline exhibited no measurable drift. A comparison between the first and last hour of operation revealed only a 0.87 ms deviation in mean latency, with no packet loss, missing updates, or misaligned states. The DT therefore remained fully synchronized with the real PLC throughout the entire evaluation period, confirming the robustness of the real-time communication channel.
In terms of command validation, the system processed a total of 1438 write attempts during user interactions. Of these, 1402 requests (97.5%) were correctly authorized and forwarded to the PLC, while 36 (2.5%) were deliberately rejected in accordance with predefined safety rules. Specifically, twenty-one were blocked by rate-limit protections after repeated button activations, eleven corresponded to redundant commands attempting to trigger an already active state, and four were denied due to lack of temporary ownership of a shared control object. No malformed packets, undefined commands, or unauthorized actions passed through the DMZ validation layer. These results confirm that the validation gateway effectively enforced operational safety and prevented conflicting or unsafe operations, even under multi-user conditions with concurrent interaction attempts.
In addition, the system demonstrated excellent stability during continuous operation. Throughout the eight-hour trial, no critical faults, reconnections, or session interruptions occurred. The telemetry broker maintained an average throughput of 22.4 updates per second with minor fluctuations of approximately ±1.3 Hz, while the metaverse session server and real-time relay consistently rendered between 72 and 75 FPS on Meta Quest 2 headsets, with no observable frame drops during periods of high interaction.
Finally, network monitoring detected only three transient warning events caused by short external Wi-Fi congestion episodes, none of which affected PLC communication or user experience. Overall system uptime during the extended test was 100%, confirming that the architecture delivers stable synchronization, robust long-term performance, and fault-free operation under realistic multi-user conditions.
3.2. Usability Evaluation
The analysis of the SUS responses shows that the metaverse interface achieved a very high perceived usability, with an overall score of 93.86 out of 100 (min 82.5; max 100; SD 3.99). This places the system well within the range associated with excellent usability in interactive environments. Figure 10 illustrates the distribution of responses for each SUS item, which is detailed in Table 1, and the numerical results are summarized in Table 2.
Figure 10.
Distribution of responses for the ten System Usability Scale (SUS) items. Bars indicate mean scores and error bars represent standard deviations on a 1–5 Likert scale. Odd-numbered items correspond to positive statements, while even-numbered items are negatively worded [55].
Table 2.
Mean and standard deviation (SD) for each SUS item across the 22 participants. Higher scores in positive items (SUS1, SUS3, SUS5, SUS7, SUS9) and low scores in negative items indicate strong perceived usability and consistency of the metaverse interface [55].
Table 3 summarises the main themes that emerged from the interview analysis and the general attitude expressed by participants toward each theme.
Table 3.
Main themes emerging from post-task interviews and participants’ attitudes.
The qualitative observations discussed in the following derive directly from the analysis of the post-task interview responses. Participants generally indicated that they would feel comfortable using the interface regularly and reported no major difficulties in completing the assigned tasks. They highlighted the coherence of the interaction elements, the intuitiveness of the controls, and the clarity of the system feedback, which contributed to a strong sense of confidence when navigating and operating the virtual cell. Many users also expressed appreciation for being able to interact with both hands free thanks to hand-tracking and valued that locomotion could be performed with a single-hand teleport gesture.
However, several participants also pointed out limitations inherent to current VR hardware and interaction modalities. A recurring comment referred to the physical weight of the headset, which caused mild discomfort after extended use. Some users also mentioned occasional failures in the teleporting gesture, which momentarily interrupted movement and generated slight frustration during navigation. While most users preferred hand-tracking for its naturalness, a subset indicated that they would sometimes rather use the controllers for precision actions or to avoid gesture-recognition errors.
Another common remark was the absence of tactile feedback when manipulating virtual objects. Although participants could see and position the added items correctly, some noted that the lack of haptic sensation diminished the realism of object handling and suggested incorporating vibration or alternative feedback strategies to strengthen the perception of contact. Despite these limitations, user comments converged on the impression that the interface was easy to learn, robust during interaction, and suitable for remote supervision and collaborative tasks.
4. Discussion
The results obtained from the technical evaluation and the user study provide consistent evidence that the proposed industrial metaverse architecture can support real-time supervision and control of a physical automation process while maintaining robustness, usability, and scalability. The quantitative measurements confirm that the system behaves reliably under the same communication conditions used by the real pick-and-place cell, demonstrating that the DT can operate as a functional surrogate of the physical system without introducing perceptual inconsistencies or synchronization drift.
The latency values achieved averaged below 45 ms for both telemetry acquisition and control-actuation propagation. These values are well within the range required for responsive interaction in industrial Human-Machine Interface (HMI) systems. The narrow jitter bands and the absence of temporal drift during the eight-hour uninterrupted test reinforce the stability of the communication pipeline and validate the design choices adopted in Section 2, particularly the use of a DMZ-based middleware layer for command validation. Previous research has highlighted the risk of performance degradation in long-running XR-based industrial applications, especially under multi-user conditions. However, the proposed architecture showed no such degradation, with stable update rates and no packet-loss incidents across the full operation period.
User study results further support the viability of the proposed approach. The SUS score of 93.86 indicates excellent perceived usability, even among participants without prior industrial or VR experience, suggesting that the interaction model is intuitive and accessible. Qualitative feedback complements these findings: users described the workflow as coherent and the controls as easy to understand, and they generally felt confident when interacting with the system. They particularly valued the freedom offered by hand-tracking and the convenience of performing teleporting with a single hand.
Nevertheless, participants also identified several limitations typical of current VR interaction paradigms. Some noted that the weight of the headset reduced comfort during longer sessions, and occasional misdetections of the teleporting gesture caused brief interruptions in navigation. A number of users indicated that, although hand-tracking was natural and convenient, they would sometimes prefer using controllers for more precise manipulation. In addition, several participants pointed out the lack of tactile feedback when interacting with virtual objects, suggesting that the incorporation of haptic cues could enhance realism and immersion. These observations do not undermine the overall usability of the system but highlight opportunities to refine interaction fidelity and ergonomics in future iterations.
Beyond hardware-related considerations, the system itself also presents several methodological and architectural limitations that should be acknowledged. First, although the communication pipeline demonstrated stable performance under the conditions tested in this study, its scalability to larger industrial deployments with higher data throughput or more complex device topologies has not yet been fully characterized. Likewise, the current implementation relies on a centralized session server for multi-user synchronization, which simplifies coordination but may constitute a single point of failure or a bottleneck in scenarios involving a significantly larger number of concurrent users.
Another limitation concerns the granularity of control supported by the metaverse interface. The validated command pathway is designed for discrete supervisory actions (e.g., start, stop, reset), but extending the system to support fine-grained continuous control or time-critical motion commands would require additional research on deterministic communication, safety guarantees, and human–machine shared autonomy. Furthermore, while the command-validation layer successfully prevents unsafe or unauthorized actions, its rule set must be manually configured; automating its adaptation to different machines or production contexts remains an open challenge.
The behavior observed in the metaverse, such as multi-user synchronization, shared manipulation of persistent virtual objects, and concurrent access to machine controls, also demonstrates that the environment supports collaboration without compromising safety or determinism. The ownership mechanism for shared interactive elements prevented conflicts between users, while the PLC ladder views confirmed that only validated, safe commands reached the physical controller. These findings reinforce the potential of industrial metaverses not only as visualization platforms but as operational interfaces enabling distributed decision-making.
While the case study successfully demonstrated the technical feasibility and usability of the proposed architecture, further validation under real industrial conditions remains essential. The current experiments were conducted using a high-fidelity DT that accurately replicated the behavior and communication interfaces of a physical cell. However, future work should extend this evaluation to a production environment involving real operators, heterogeneous network conditions, and plant-scale workloads. Testing the methodology in an operational setting would allow us to assess how experienced personnel interact with the system during routine and high-demand scenarios, and whether the same levels of synchronization accuracy, responsiveness, and perceived usability can be maintained. Such validation will determine whether the results obtained in this study are fully consolidated or if methodological adjustments are required to accommodate the complexities of real industrial processes.
It is important to clarify, however, that although the present validation involved a real industrial controller, a Siemens S7-1200 PLC (from Siemens manufacturer, located in Munich, Germany), the physical process it supervises was intentionally replaced by a high-fidelity digital twin to ensure repeatability, eliminate safety risks, and enable long-duration multi-user testing. This design choice does not imply that the architecture is limited to virtual–virtual interaction; rather, it reflects a controlled evaluation strategy. Fully integrating the proposed metaverse architecture with a real industrial process remains an essential step for future work.
To illustrate the applicability of the system beyond the laboratory scenario, Figure 11 includes an additional example based on a real automated inspection tunnel installed at the Mercedes-Benz factory in Vitoria (Spain) [61]. The corresponding metaverse environment, constructed using the same modelling, synchronization, and validation methodology outlined in this work, enables operators to observe real objects (vehicles) moving through the tunnel, experiment with camera-placement strategies, and understand the impact of inspection parameters in an immersive setting. These examples constitute preliminary demonstrations that the proposed architecture can be transferred to real industrial assets, and work is currently underway to complete the full integration of the inspection system following the methodology described in this paper.
Figure 11.
Real industrial inspection tunnel and its preliminary metaverse representation. (a) Automated defect-detection tunnel installed at the Mercedes-Benz factory in Vitoria (Spain) [61]. (b–e) Preliminary metaverse environment under development following the methodology presented in this work. The virtual scene reproduces the tunnel layout and allows operators to visualize object flow, explore inspection angles, and evaluate camera-placement strategies in an immersive manner.
5. Conclusions
This work presented and validated an industrial metaverse architecture capable of enabling real-time interaction, supervision, and control of a physical automation system through a multi-user immersive environment. The proposed case study integrated a digital twin synchronized with a real PLC, a command-validation gateway enforcing safety and access constraints, and a multi-user metaverse interface supporting persistent shared objects and collaborative manipulation.
The technical evaluation demonstrated that the system maintained high synchronization accuracy and low latency, even during extended operation. With end-to-end delays consistently below 45 ms, minimal jitter, and no temporal drift across an eight-hour uninterrupted test, the architecture satisfied the performance requirements of industrial human-machine interface applications. Additionally, the validation subsystem correctly processed all control requests, rejecting only those violating predefined safety or rate-limit rules and ensuring that no unsafe or malformed command reached the PLC.
The user study confirmed the accessibility and usability of the metaverse interface. Participants, including non-experts, achieved a SUS score of 93.86, highlighting excellent perceived usability and suggesting that the system is suitable for operators with varying levels of technical expertise. Multi-user interaction, shared object persistence, and real-time audio–visual communication were all handled smoothly, reinforcing the suitability of the proposed environment for collaborative industrial tasks.
Moreover, the methodology could be extended to incorporate more advanced visual features in the digital twin, such as realistic materials, textures, and lighting, in order to further enhance immersion and support training-oriented use cases. While these attributes are not required for real-time control or synchronization, they can enrich the perceptual quality of industrial metaverse environments and strengthen the connection between virtual and physical realms.
Overall, industrial metaverses offer a viable path toward remote supervision and collaboration when they are combined with validated communication pipelines and real digital-physical synchronization. Future work will focus on extending the validation of the proposed methodology to real production environments involving expert operators and authentic industrial workloads. Such evaluation is essential to determine whether the performance, stability, and usability observed in this study remain consistent under real operating constraints. In addition, user feedback revealed several aspects that warrant further refinement, including occasional gesture-recognition errors, the ergonomics of prolonged headset use, and the absence of tactile feedback during object manipulation. Addressing these limitations through improved locomotion gestures, optional controller-based interaction, and the integration of lightweight haptic cues will help enhance the realism and operational suitability of the industrial metaverse.
Author Contributions
Conceptualization, J.E.S.; Methodology, J.E.S.; Validation, A.F.-F.; Formal analysis, J.E.S. and L.G.; Investigation, J.E.S.; Resources, L.G. and A.M.; Data curation, A.F.-F.; Writing—original draft, J.E.S.; Writing—review & editing, A.F.-F., L.G. and A.M.; Supervision, L.G. and A.M.; Project administration, A.M.; Funding acquisition, L.G. and A.M. All authors have read and agreed to the published version of the manuscript.
Funding
This work has received funding from the European Union’s DIGITAL Europe Programme under Grant Agreement No. 101226207 (project AI-SECRETT), from the Spanish Government under Grant PID2024-156583OB-I00 (funded by MICIU/AEI/10.13039/501100011033), and from the Generalitat Valenciana under Grant CIGE/2024/195.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Tao, F.; Zhang, M.; Liu, Y.; Nee, A.Y.C. Digital Twin in Industry: State-of-the-Art. IEEE Trans. Ind. Inform. 2019, 15, 2405–2415. [Google Scholar] [CrossRef] [Scilit]
- Grieves, M. Digital Twin: Manufacturing Excellence through Virtual Factory Replication. White Pap. 2014, 1, 1–7. [Google Scholar]
- Wang, Y.; Chen, X.; Liu, Z. Augmented Reality and Virtual Reality in Smart Factories: Enhancing Remote Collaboration and Decision-Making. J. Manuf. Syst. 2021, 60, 1–12. [Google Scholar] [CrossRef] [Scilit]
- Kumar Kar, A.; Mikalef, P.; Nishant, R.; Luo, X.; Gupta, M. Metaverse opportunities and challenges: A research agenda and editorial on the special issue on the evolution of Metaverse platforms (part 2). Decis. Support Syst. 2025, 194, 114456. [Google Scholar] [CrossRef] [Scilit]
- Kumar, L.; Lovén, H.; Talha, J.; Talha Arshad, M.; Pirttikangas, S.; Tarkoma, S. Towards a data fabric framework for industrial metaverse integration. Sustain. Comput. Inform. Syst. 2025, 47, 101132. [Google Scholar] [CrossRef] [Scilit]
- Patel, D.; Manickam, R. Enhancing Maintenance Learning in the Industrial Metaverse: Integrating Virtual Reality and Machine Learning. In Industry 4.0 and Advanced Manufacturing; Springer Nature Singapore: Singapore, 2025; pp. 153–163. [Google Scholar] [CrossRef] [Scilit]
- Almeida, L.G.G.; Vasconcelos, N.V.d.; Winkler, I.; Catapan, M.F. Innovating Industrial Training with Immersive Metaverses: A Method for Developing Cross-Platform Virtual Reality Environments. Appl. Sci. 2023, 13, 8915. [Google Scholar] [CrossRef] [Scilit]
- Ren, L.; Zhang, X.; Zhang, Y.; Liu, J.; Zhang, Y.; Wang, F.; Chen, Z.; Chen, C. Industrial Metaverse for Smart Manufacturing: Model, Architecture, and Applications. IEEE Trans. Cybern. 2024, 54, 2683–2696. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Siemens Digital Twin—Real-Time Data Integration, Simulation and Control. 2025. Available online: https://www.sw.siemens.com/en-US/technology/digital-twin/ (accessed on 5 December 2025).
- Rockwell Automation Building Factory of the Future with Digital Twins. 2024. Available online: https://www.rockwellautomation.com/en-gb/company/news/blogs/digi-twin-factory-future.html (accessed on 5 December 2025).
- Dassault Systemes DELMIA—Digital Manufacturing & Virtual Twin Solution. 2025. Available online: https://en.wikipedia.org/wiki/DELMIA (accessed on 5 December 2025).
- Kaman, Z. Mapping 4000 Global Industrial Automation Projects: Vendor Footprints and Trends. 2025. Available online: https://iot-analytics.com/industrial-automation-projects/ (accessed on 5 December 2025).
- Henkel, D.A.; Ivens, B.S. Conceptualizing the Industrial Metaverse: From Technological Layers to Business Value. Ind. Mark. Manag. 2025, 131, 58–72. [Google Scholar] [CrossRef] [Scilit]
- ABB. Industrial Metaverse|News Center. 2023. Available online: https://new.abb.com/news/detail/103099/industrial-metaverse (accessed on 5 December 2025).
- Xiao, X.; Roy, R.; Omidyeganeh, M.; Furnari, F. Industrial Metaverse design methodologies: A comprehensive literature review. Int. J. Comput. Integr. Manuf. 2025, 1–31, (in press). [Google Scholar] [CrossRef] [Scilit]
- Rockwell Automation Emulate3D Digital Twin Software. 2024. Available online: https://www.rockwellautomation.com/en-us/products/software/factorytalk/designsuite/emulate3d-digital-twin.html (accessed on 5 December 2025).
- Siemens. Industrial DMZ Infrastructure. Technical Report, Siemens Digital Enterprise Services. 2024. Available online: https://assets.new.siemens.com/siemens/assets/api/uuid:7cbfc3d8-cff9-49a4-9ab3-7e189f0bfc2d/IDMZ-Presentation-EN_original.pdf (accessed on 5 December 2025).
- Emma Junior, E.; Mgbemele, A.F.; Adebisi, O.O. Cybersecurity Risks and Defense Strategies in Digital-Twin-Enabled Smart Infrastructure: A Systematic Review. SSRN Electron. J. 2025, 6, 193–198. [Google Scholar] [CrossRef] [Scilit]
- Wang, K.; Wang, Y.; Li, Y.; Fan, X.; Xiao, S.; Hu, L. A review of the technology standards for enabling digital twin. Digit. Twin 2024, 1, 4. [Google Scholar] [CrossRef] [Scilit]
- Mertes, J.; Schellenberger, C.; Yi, L.; Schmitz, M.; Glatt, M.; Klar, M.; Ravani, B.; Schotten, H.D.; Aurich, J.C. Experimental evaluation of 5G performance based on a digital twin of a machine tool. CIRP J. Manuf. Sci. Technol. 2024, 55, 141–152. [Google Scholar] [CrossRef] [Scilit]
- Siemens. El Emergente Metaverso Industrial. Technical Report, Siemens, 2023. Available online: https://assets.new.siemens.com/siemens/assets/api/uuid:83a5d2e2-32e8-4bc5-bb9f-784dccb77d3a/Metaverso-Industrial.pdf (accessed on 5 December 2025).
- Hosseini, S.; Abbasi, A.; Magalhaes, L.G.; Fonseca, J.C.; da Costa, N.M.; Moreira, A.H.; Borges, J. Immersive Interaction in Digital Factory: Metaverse in Manufacturing. Procedia Comput. Sci. 2024, 232, 2310–2320. [Google Scholar] [CrossRef] [Scilit]
- Zahid, A.; Ferraro, A.; Petrillo, A.; De Felice, F. Exploring the Role of Digital Twin and Industrial Metaverse Technologies in Enhancing Occupational Health and Safety in Manufacturing. Appl. Sci. 2025, 15, 8268. [Google Scholar] [CrossRef] [Scilit]
- Lee, J.; Kundu, P. Integrated cyber-physical systems and industrial metaverse for remote manufacturing. Manuf. Lett. 2022, 34, 12–15. [Google Scholar] [CrossRef] [Scilit]
- Ara, A. Security in Supervisory Control and Data Acquisition (SCADA) based Industrial Control Systems: Challenges and Solutions. IOP Conf. Ser. Earth Environ. Sci. 2022, 1026, 012030. [Google Scholar] [CrossRef] [Scilit]
- Sammarco, J. Programmable electronic and hardwired emergency shutdown systems: A quantified safety analysis. In Proceedings of the Fourtieth IAS Annual Meeting. Conference Record of the 2005 Industry Applications Conference, Hong Kong, China, 2–6 October 2005; Volume 1, pp. 210–217. [Google Scholar] [CrossRef] [Scilit]
- IEC 61508; Functional Safety of Electrical/Electronic/Programmable Electronic Safety-Related Systems. International Electrotechnical Commission: Geneva, Switzerland, 2010.
- Skourup, C.; Pretlove, J. Remote Inspection and Intervention: Remote Robotics at Work in Harsh Oil and Gas Environments. Technical Report, ABB, 2015. Available online: https://library.e.abb.com/public/46a3a908e1a647f3c125795800580caf/50-55%202m155_ENG_72dpi.pdf (accessed on 5 December 2025).
- Siemens, A.G. Calibration and Verification: Reliability and Availability in Your Processes with Our Instrumentation Services. Industry Services Documentation, Siemens, 2022. Available online: https://assets.new.siemens.com/siemens/assets/api/uuid:dea20cd3e346c479fd86fb2320969e797d1f026e/process-instrumentation-services-calibration-and-verification-en.pdf (accessed on 5 December 2025).
- Mathrani, S.; Edwards, B. Knowledge-Sharing Strategies in Distributed Collaborative Product Development. J. Open Innov. Technol. Mark. Complex. 2020, 6, 194. [Google Scholar] [CrossRef] [Scilit]
- Wang, L. Web-based decision making for collaborative manufacturing. Int. J. Comput. Integr. Manuf. 2009, 22, 334–344. [Google Scholar] [CrossRef] [Scilit]
- Li, Q.; Yang, Y.; Jiang, P. Remote Monitoring and Maintenance for Equipment and Production Lines on Industrial Internet: A Literature Review. Machines 2023, 11, 12. [Google Scholar] [CrossRef] [Scilit]
- Ferretti, L.; Longo, F.; Merlino, G.; Colajanni, M.; Puliafito, A.; Tapas, N. Verifiable and auditable authorizations for smart industries and industrial Internet-of-Things. J. Inf. Secur. Appl. 2021, 59, 102848. [Google Scholar] [CrossRef] [Scilit]
- Lyu, Z.; Fridenfalk, M. Digital twins for building industrial metaverse. J. Adv. Res. 2024, 66, 31–38. [Google Scholar] [CrossRef] [Scilit]
- Mourtzis, D.; Zogopoulos, V.; Xanthi, F. Virtual Reality for Workforce Training in Industry 4.0. Procedia CIRP 2020, 88, 123–128. [Google Scholar] [CrossRef] [Scilit]
- Fernández-Caramés, T.M.; Fraga-Lamas, P. Forging the Industrial Metaverse for Industry 5.0: Where Extended Reality, IIoT, Opportunistic Edge Computing, and Digital Twins Meet. IEEE Access 2024, 12, 95778–95819. [Google Scholar] [CrossRef] [Scilit]
- Tu, X.; Ala-Laurinaho, R.; Yang, C.; Autiosalo, J.; Tammi, K. Architecture for data-centric and semantic-enhanced industrial metaverse: Bridging physical factories and virtual landscape. J. Manuf. Syst. 2024, 74, 965–979. [Google Scholar] [CrossRef] [Scilit]
- Hasan, H.R.; Madine, M.; Musamih, A.; Jayaraman, R.; Salah, K.; Yaqoob, I.; Omar, M. Non-fungible tokens (NFTs) for digital twins in the industrial metaverse: Overview, use cases, and open challenges. Comput. Ind. Eng. 2024, 193, 110315. [Google Scholar] [CrossRef] [Scilit]
- Endres, H.; Indulska, M.; Ghosh, A. Unlocking the potential of Industrial Internet of Things (IIOT) in the age of the industrial metaverse: Business models and challenges. Ind. Mark. Manag. 2024, 119, 90–107. [Google Scholar] [CrossRef] [Scilit]
- García, A.; Gracia, L.; Solanes, J.E.; Girbés-Juan, V.; Perez-Vidal, C.; Tornero, J. Robotic assistance for industrial sanding with a smooth approach to the surface and boundary constraints. Comput. Ind. Eng. 2021, 158, 107366. [Google Scholar] [CrossRef] [Scilit]
- Borrell, J.; González, A.; Perez-Vidal, C.; Gracia, L.; Solanes, J.E. Cooperative human–robot polishing for the task of patina growing on high-quality leather shoes. Int. J. Adv. Manuf. Technol. 2023, 125, 2467–2484. [Google Scholar] [CrossRef] [Scilit]
- Xie, J.; Yang, C.; Li, G.; Wang, X.; Li, X. A new XR-based human-robot collaboration assembly system based on industrial metaverse. J. Manuf. Syst. 2024, 74, 949–964. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Xie, H.L.; Zheng, P.; Wang, L. Industrial Metaverse: A proactive human-robot collaboration perspective. J. Manuf. Syst. 2024, 76, 314–319. [Google Scholar] [CrossRef] [Scilit]
- Sadeghi R., K.; Ojha, D.; Kaur, P.; Mahto, R.V.; Dhir, A. Metaverse technology in sustainable supply chain management: Experimental findings. Decis. Support Syst. 2025, 191, 114423. [Google Scholar] [CrossRef] [Scilit]
- Cao, J.; Zhu, X.; Sun, S.; Wei, Z.; Jiang, Y.; Wang, J.; Lau, V.K.N. Toward industrial metaverse: Age of information, latency and reliability of short-packet transmission in 6G. IEEE Wirel. Commun. 2023, 30, 40–47. [Google Scholar] [CrossRef] [Scilit]
- Bamberger, B.; Reinartz, W.; Ulaga, W. Navigating the future of B2B marketing: The transformative impact of the industrial metaverse. J. Bus. Res. 2025, 188, 115057. [Google Scholar] [CrossRef] [Scilit]
- Arena, F.; Collotta, M.; Luca, L.; Ruggieri, M.; Termine, F.G. Predictive Maintenance in the Automotive Sector: A Literature Review. Math. Comput. Appl. 2022, 27, 2. [Google Scholar] [CrossRef] [Scilit]
- Kour, R.; Karim, R.; Venkatesh, S.N.; Kumar, U. Metaverse in industrial contexts: A comprehensive review. Front. Virtual Real. 2025, 6, 1488926. [Google Scholar] [CrossRef] [Scilit]
- NVIDIA. Industrial Facility Digital Twins—Use Case. 2024. Available online: https://www.nvidia.com/en-us/use-cases/industrial-facility-digital-twins/ (accessed on 5 December 2025).
- NVIDIA. How Digital Twins Are Scaling Industrial AI. 2025. Available online: https://blogs.nvidia.com/blog/how-digital-twins-scale-industrial-ai/ (accessed on 5 December 2025).
- Simulation, C. The Challenges and Limitations of Digital Twin Systems and How to Overcome Them. 2024. Available online: https://cloudsimulation.dev/article/The_challenges_and_limitations_of_digital_twin_systems_and_how_to_overcome_them.html (accessed on 5 December 2025).
- Ali, A.R.; Kamal, H. Real-Time Digital Twin-Driven Optimization of Industrial Machinery. In Proceedings of the 2025 15th International Conference on Electrical Engineering (ICEENG), Cairo, Egypt, 12–15 May 2025; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Maheshwari, P.; Kamble, S.; Belhadi, A.; Venkatesh, M.; Abedin, M.Z. Digital twin-driven real-time planning, monitoring, and controlling in food supply chains. Technol. Forecast. Soc. Change 2023, 195, 122799. [Google Scholar] [CrossRef] [Scilit]
- Unity. Game Development Platform. Available online: https://unity.com/ (accessed on 11 March 2024).
- Brooke, J. “SUS—A Quick and Dirty Usability Scale.” Usability Evaluation in Industry; CRC Press: Boca Raton, FL, USA, 1996; ISBN 9780748404605. [Google Scholar]
- Blattgerste, J.; Strenge, B.; Renner, P.; Pfeiffer, T.; Essig, K. Comparing Conventional and Augmented Reality Instructions for Manual Assembly Tasks. In Proceedings of the 10th International Conference on PErvasive Technologies Related to Assistive Environments, Island of Rhodes, Greece, 21–23 June 2017; ACM: New York, NY, USA, 2017; pp. 75–82. [Google Scholar] [CrossRef] [Scilit]
- Attig, C.; Wessel, D.; Franke, T. Assessing Personality Differences in Human-Technology Interaction: An Overview of Key Self-report Scales to Predict Successful Interaction. In Proceedings of the HCI International 2017–Posters’ Extended Abstracts, Vancouver, BC, Canada, 9–14 July 2017; Stephanidis, C., Ed.; Springer: Cham, Switzerland, 2017; pp. 19–29. [Google Scholar]
- Franke, T.; Attig, C.; Wessel, D. A Personal Resource for Technology Interaction: Development and Validation of the Affinity for Technology Interaction (ATI) Scale. Int. J. Hum.-Comput. Interact. 2019, 35, 456–467. [Google Scholar] [CrossRef] [Scilit]
- Fabra, L.; Solanes, J.E.; Muñoz, A.; Martí-Testón, A.; Alabau, A.; Gracia, L. Application of Neural Radiance Fields (NeRFs) for 3D Model Representation in the Industrial Metaverse. Appl. Sci. 2024, 14, 1825. [Google Scholar] [CrossRef] [Scilit]
- Solanes, J.E.; Muñoz, A.; Gracia, L.; Tornero, J. Virtual Reality-Based Interface for Advanced Assisted Mobile Robot Teleoperation. Appl. Sci. 2022, 12, 6071. [Google Scholar] [CrossRef] [Scilit]
- Molina, J.; Solanes, J.E.; Arnal, L.; Tornero, J. On the detection of defects on specular car body surfaces. Robot. Comput.-Integr. Manuf. 2017, 48, 263–278. [Google Scholar] [CrossRef] [Scilit]
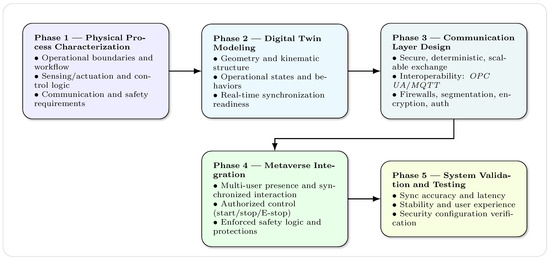
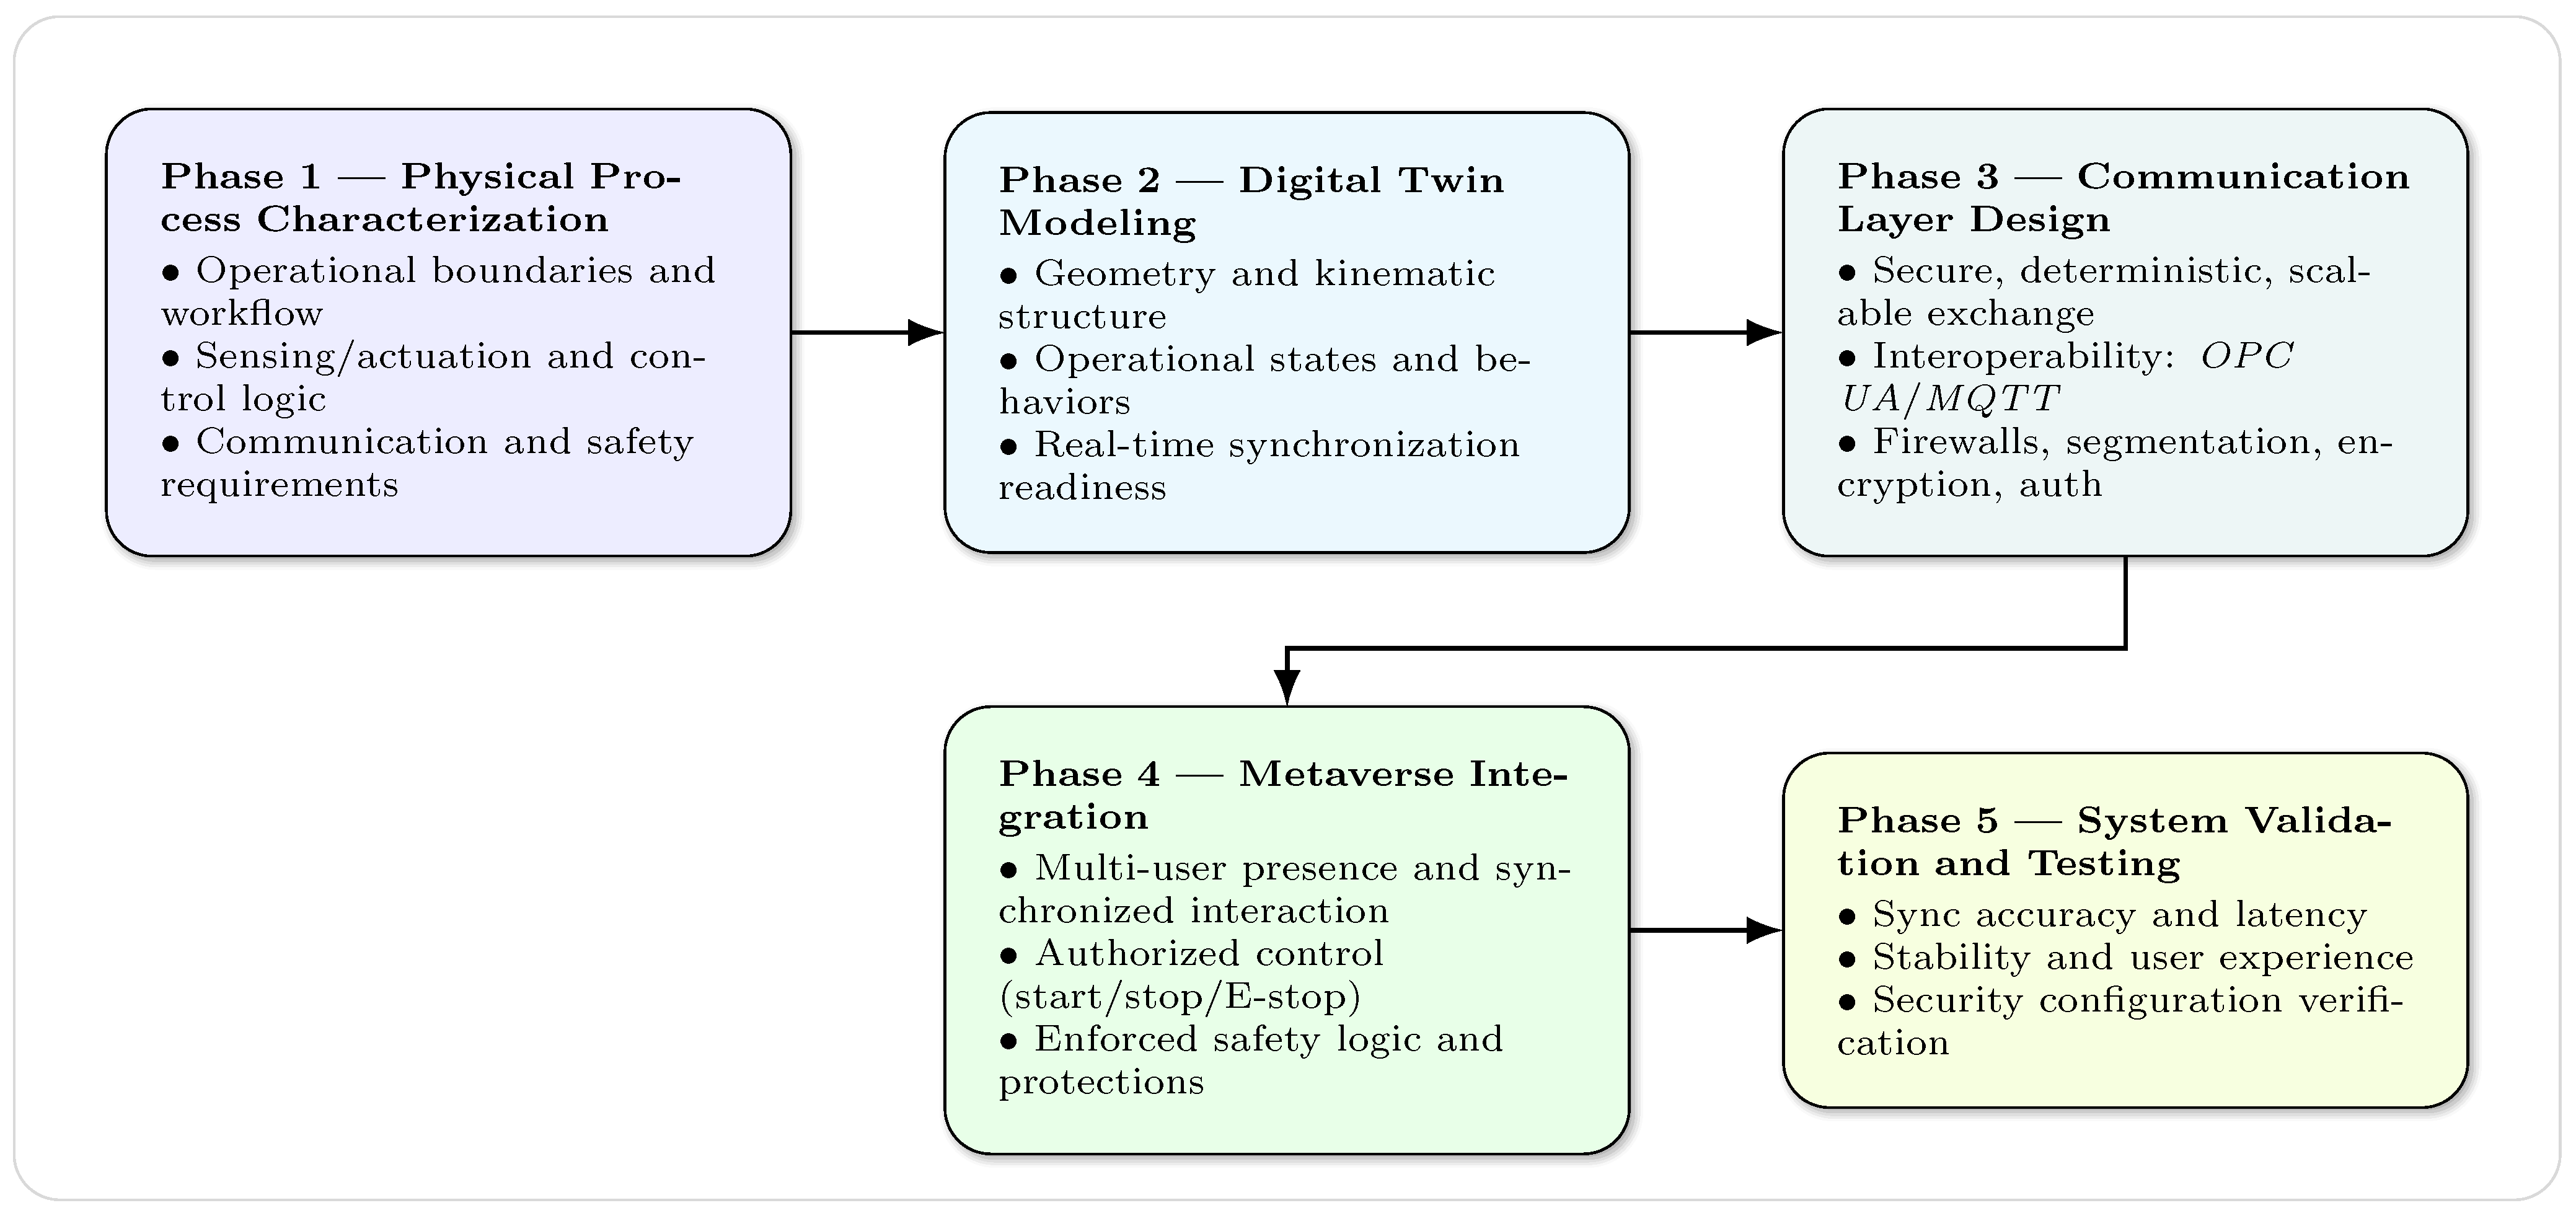
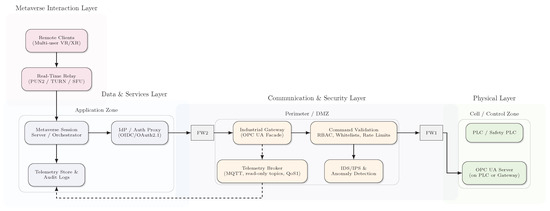
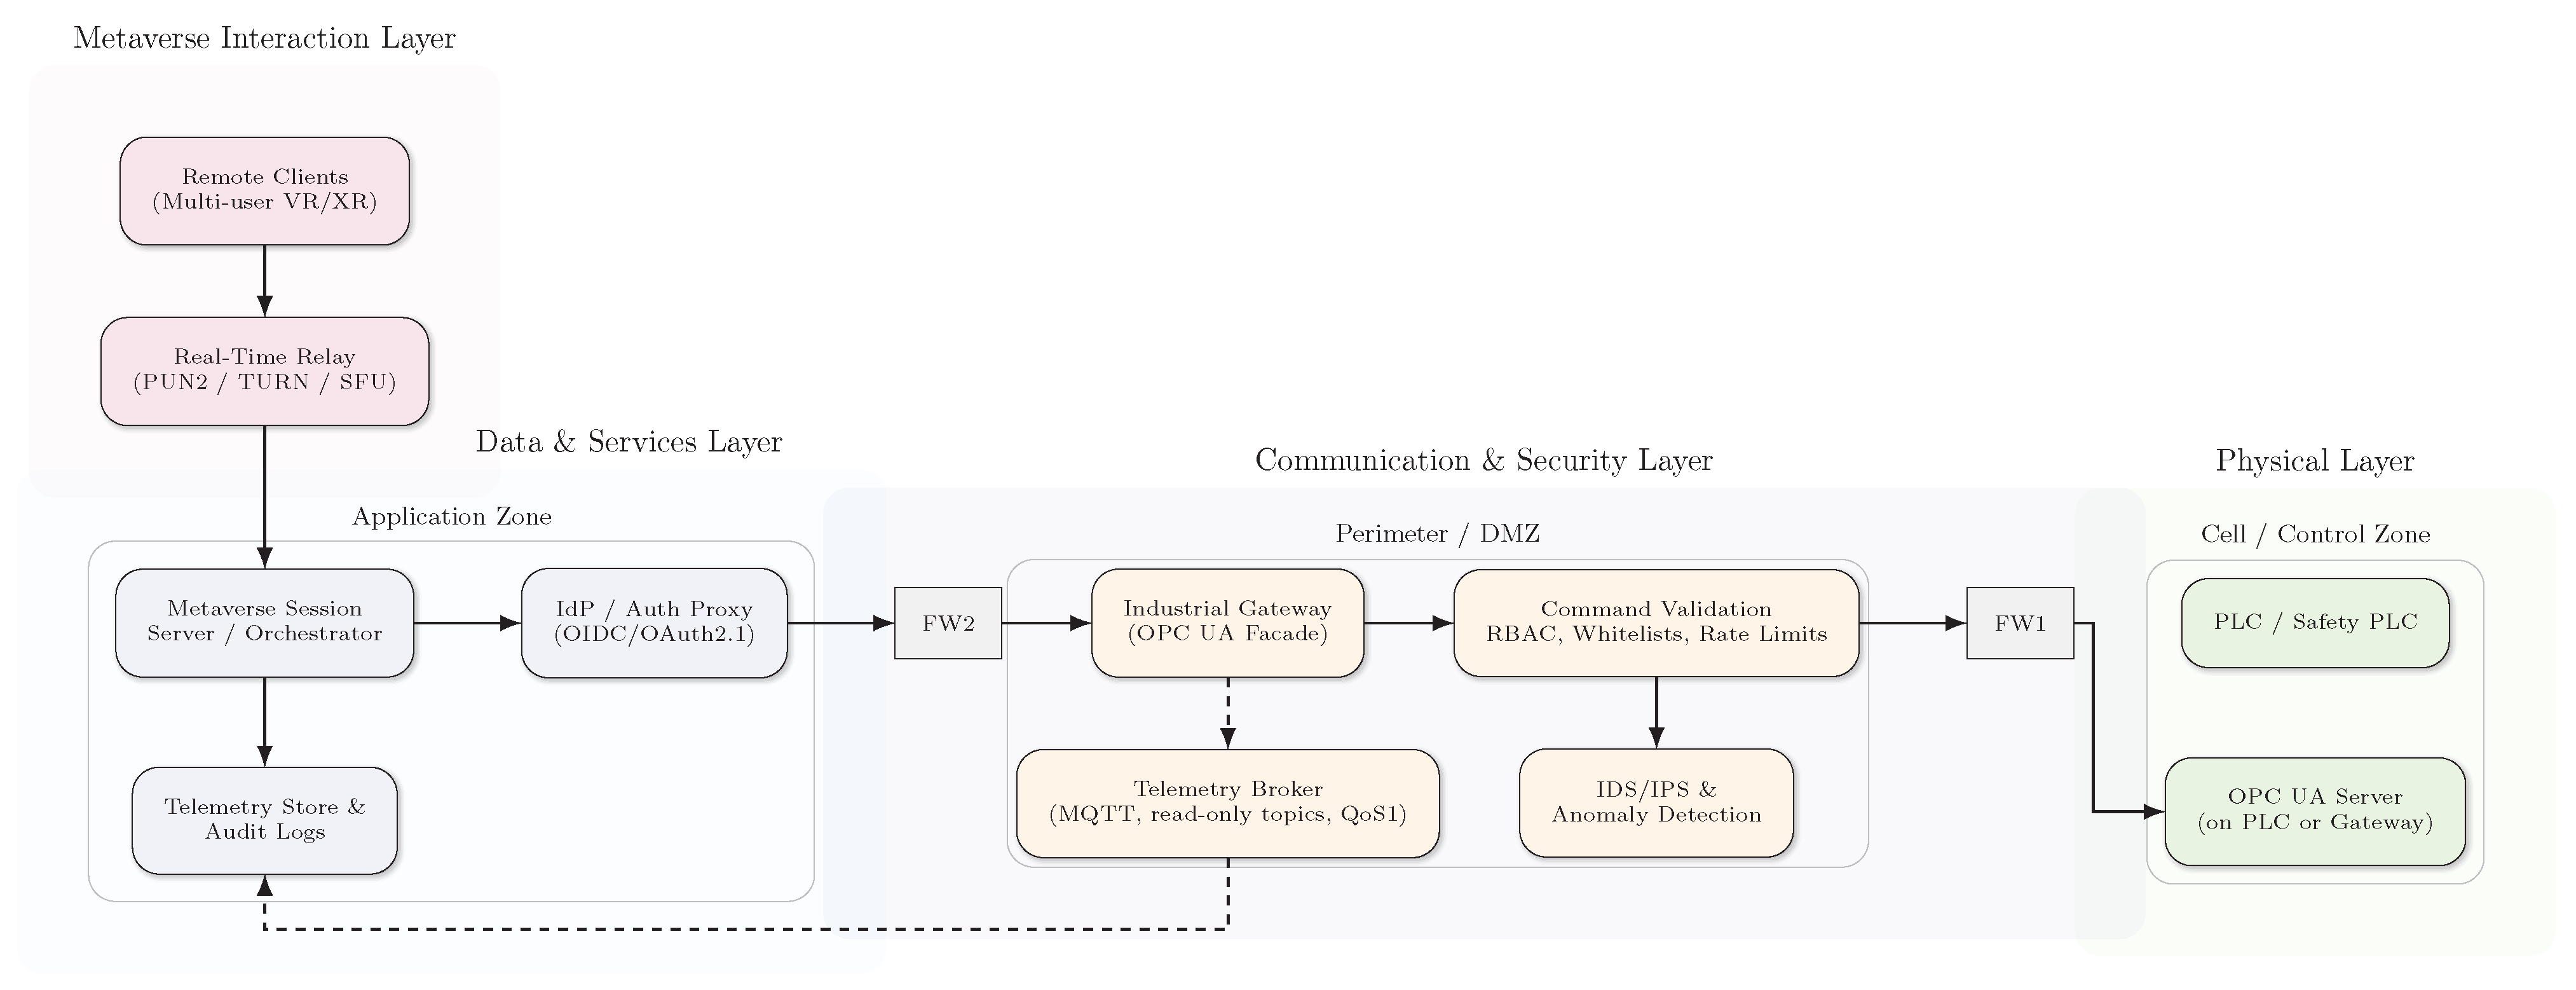
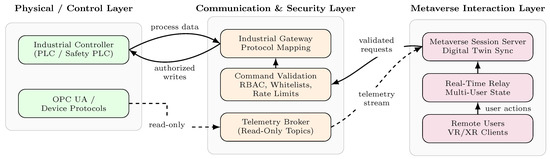
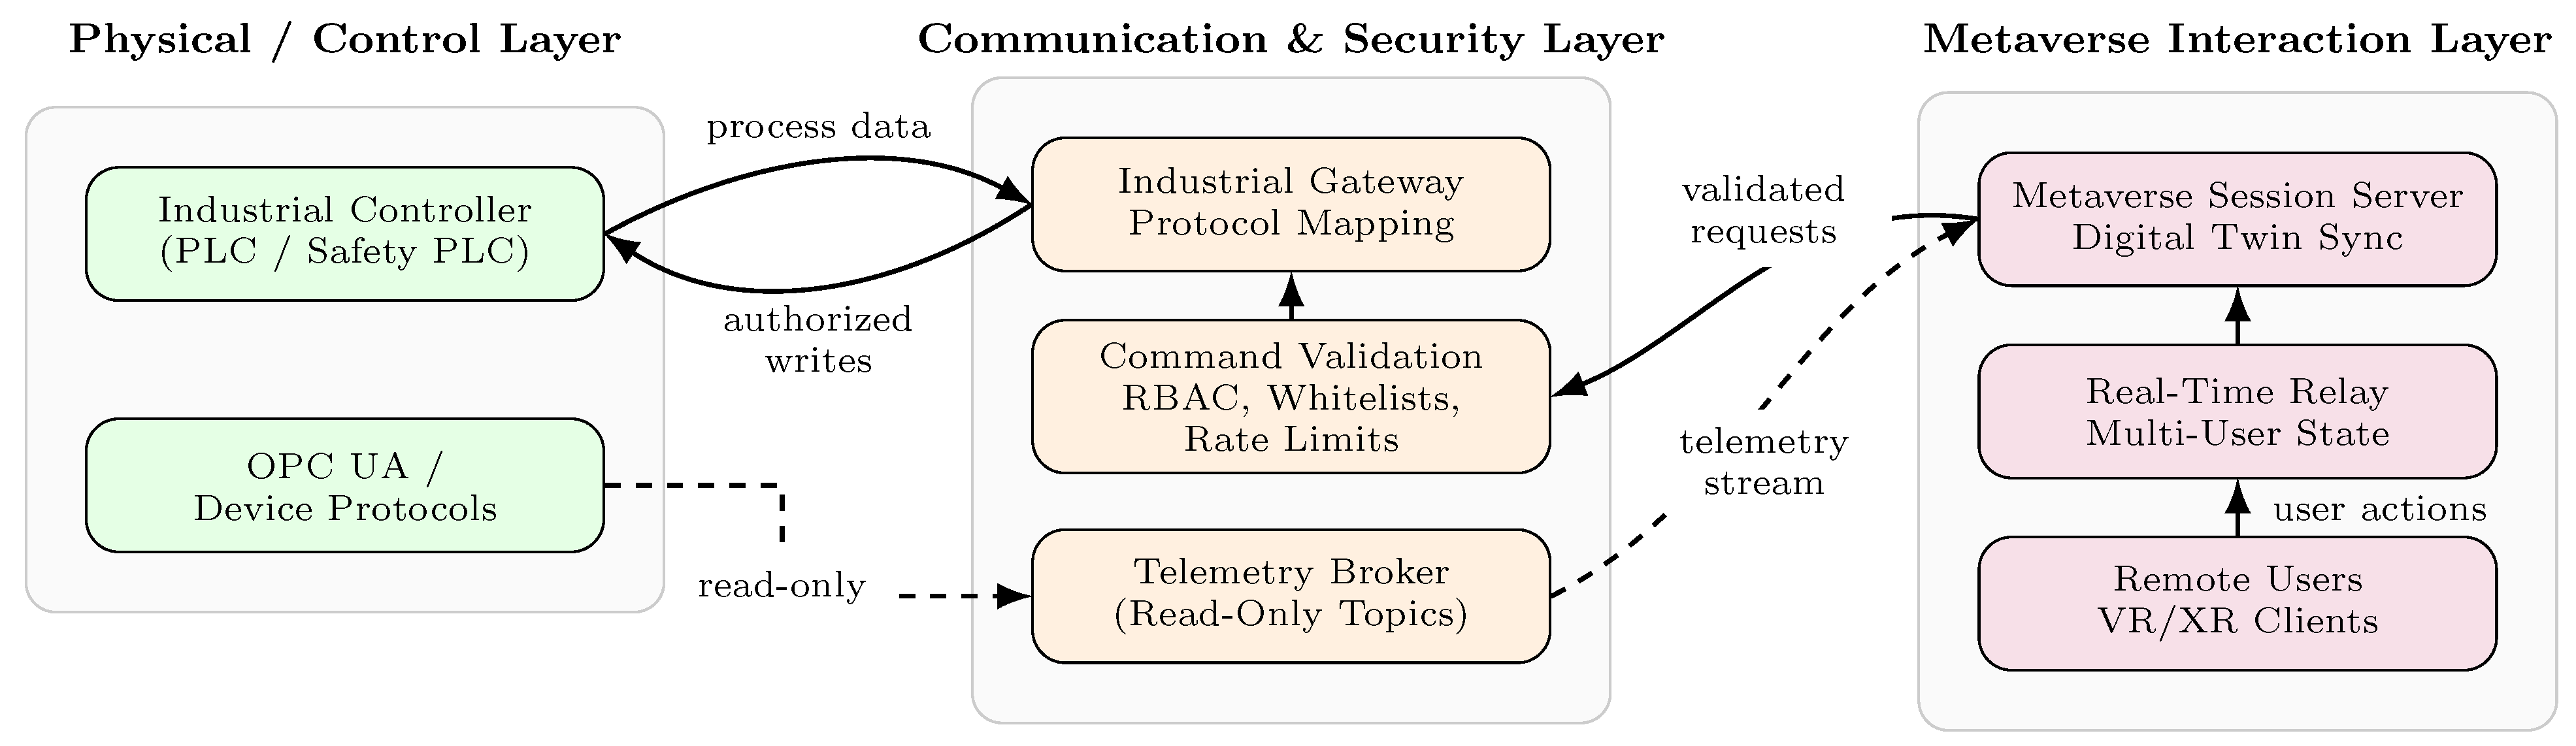
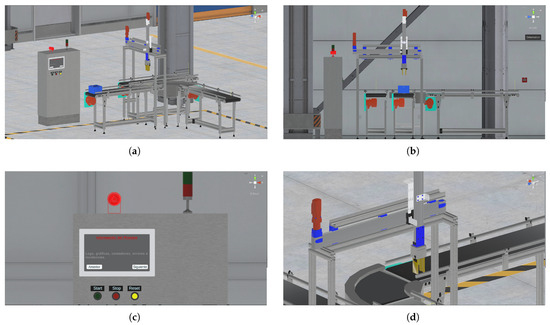
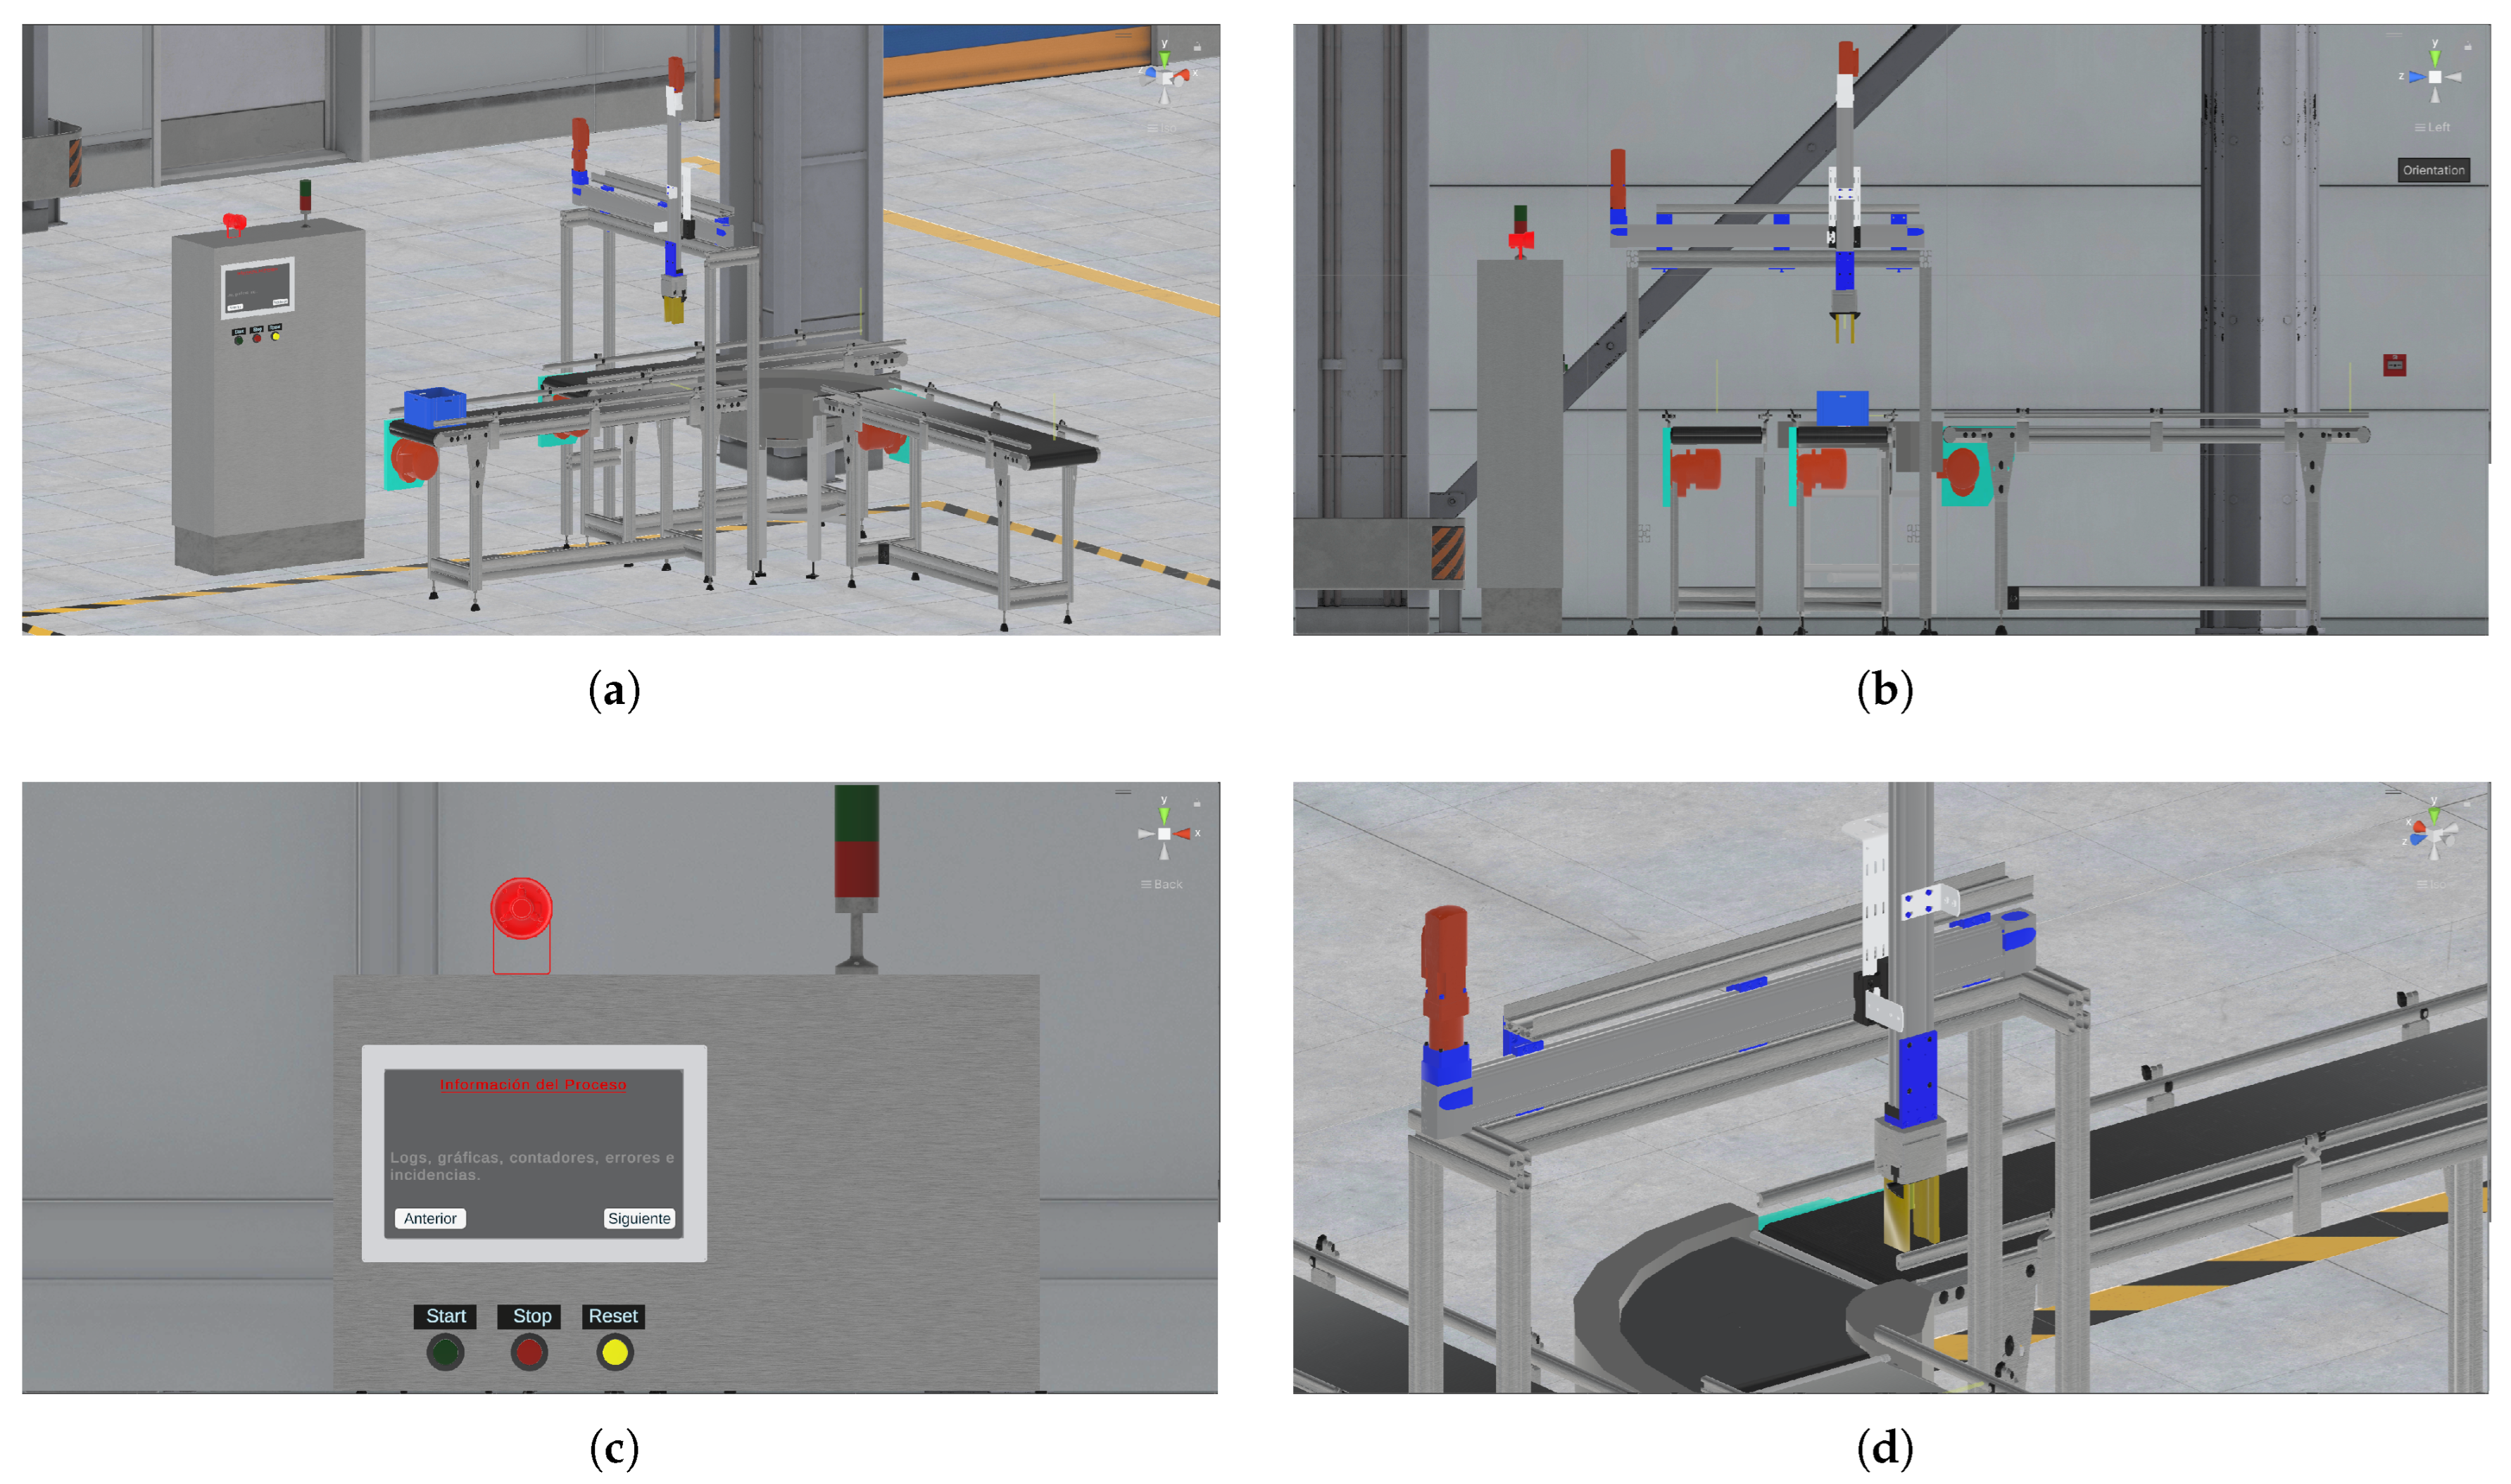
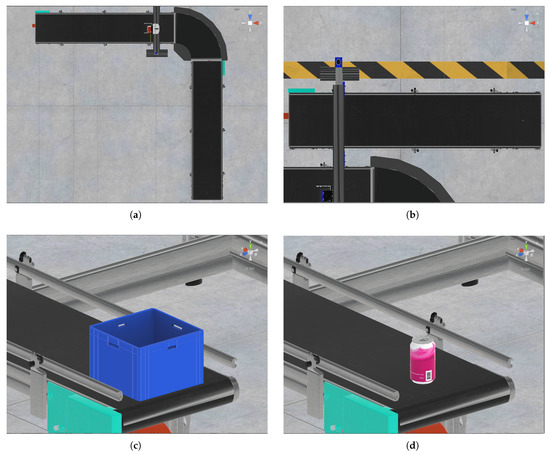
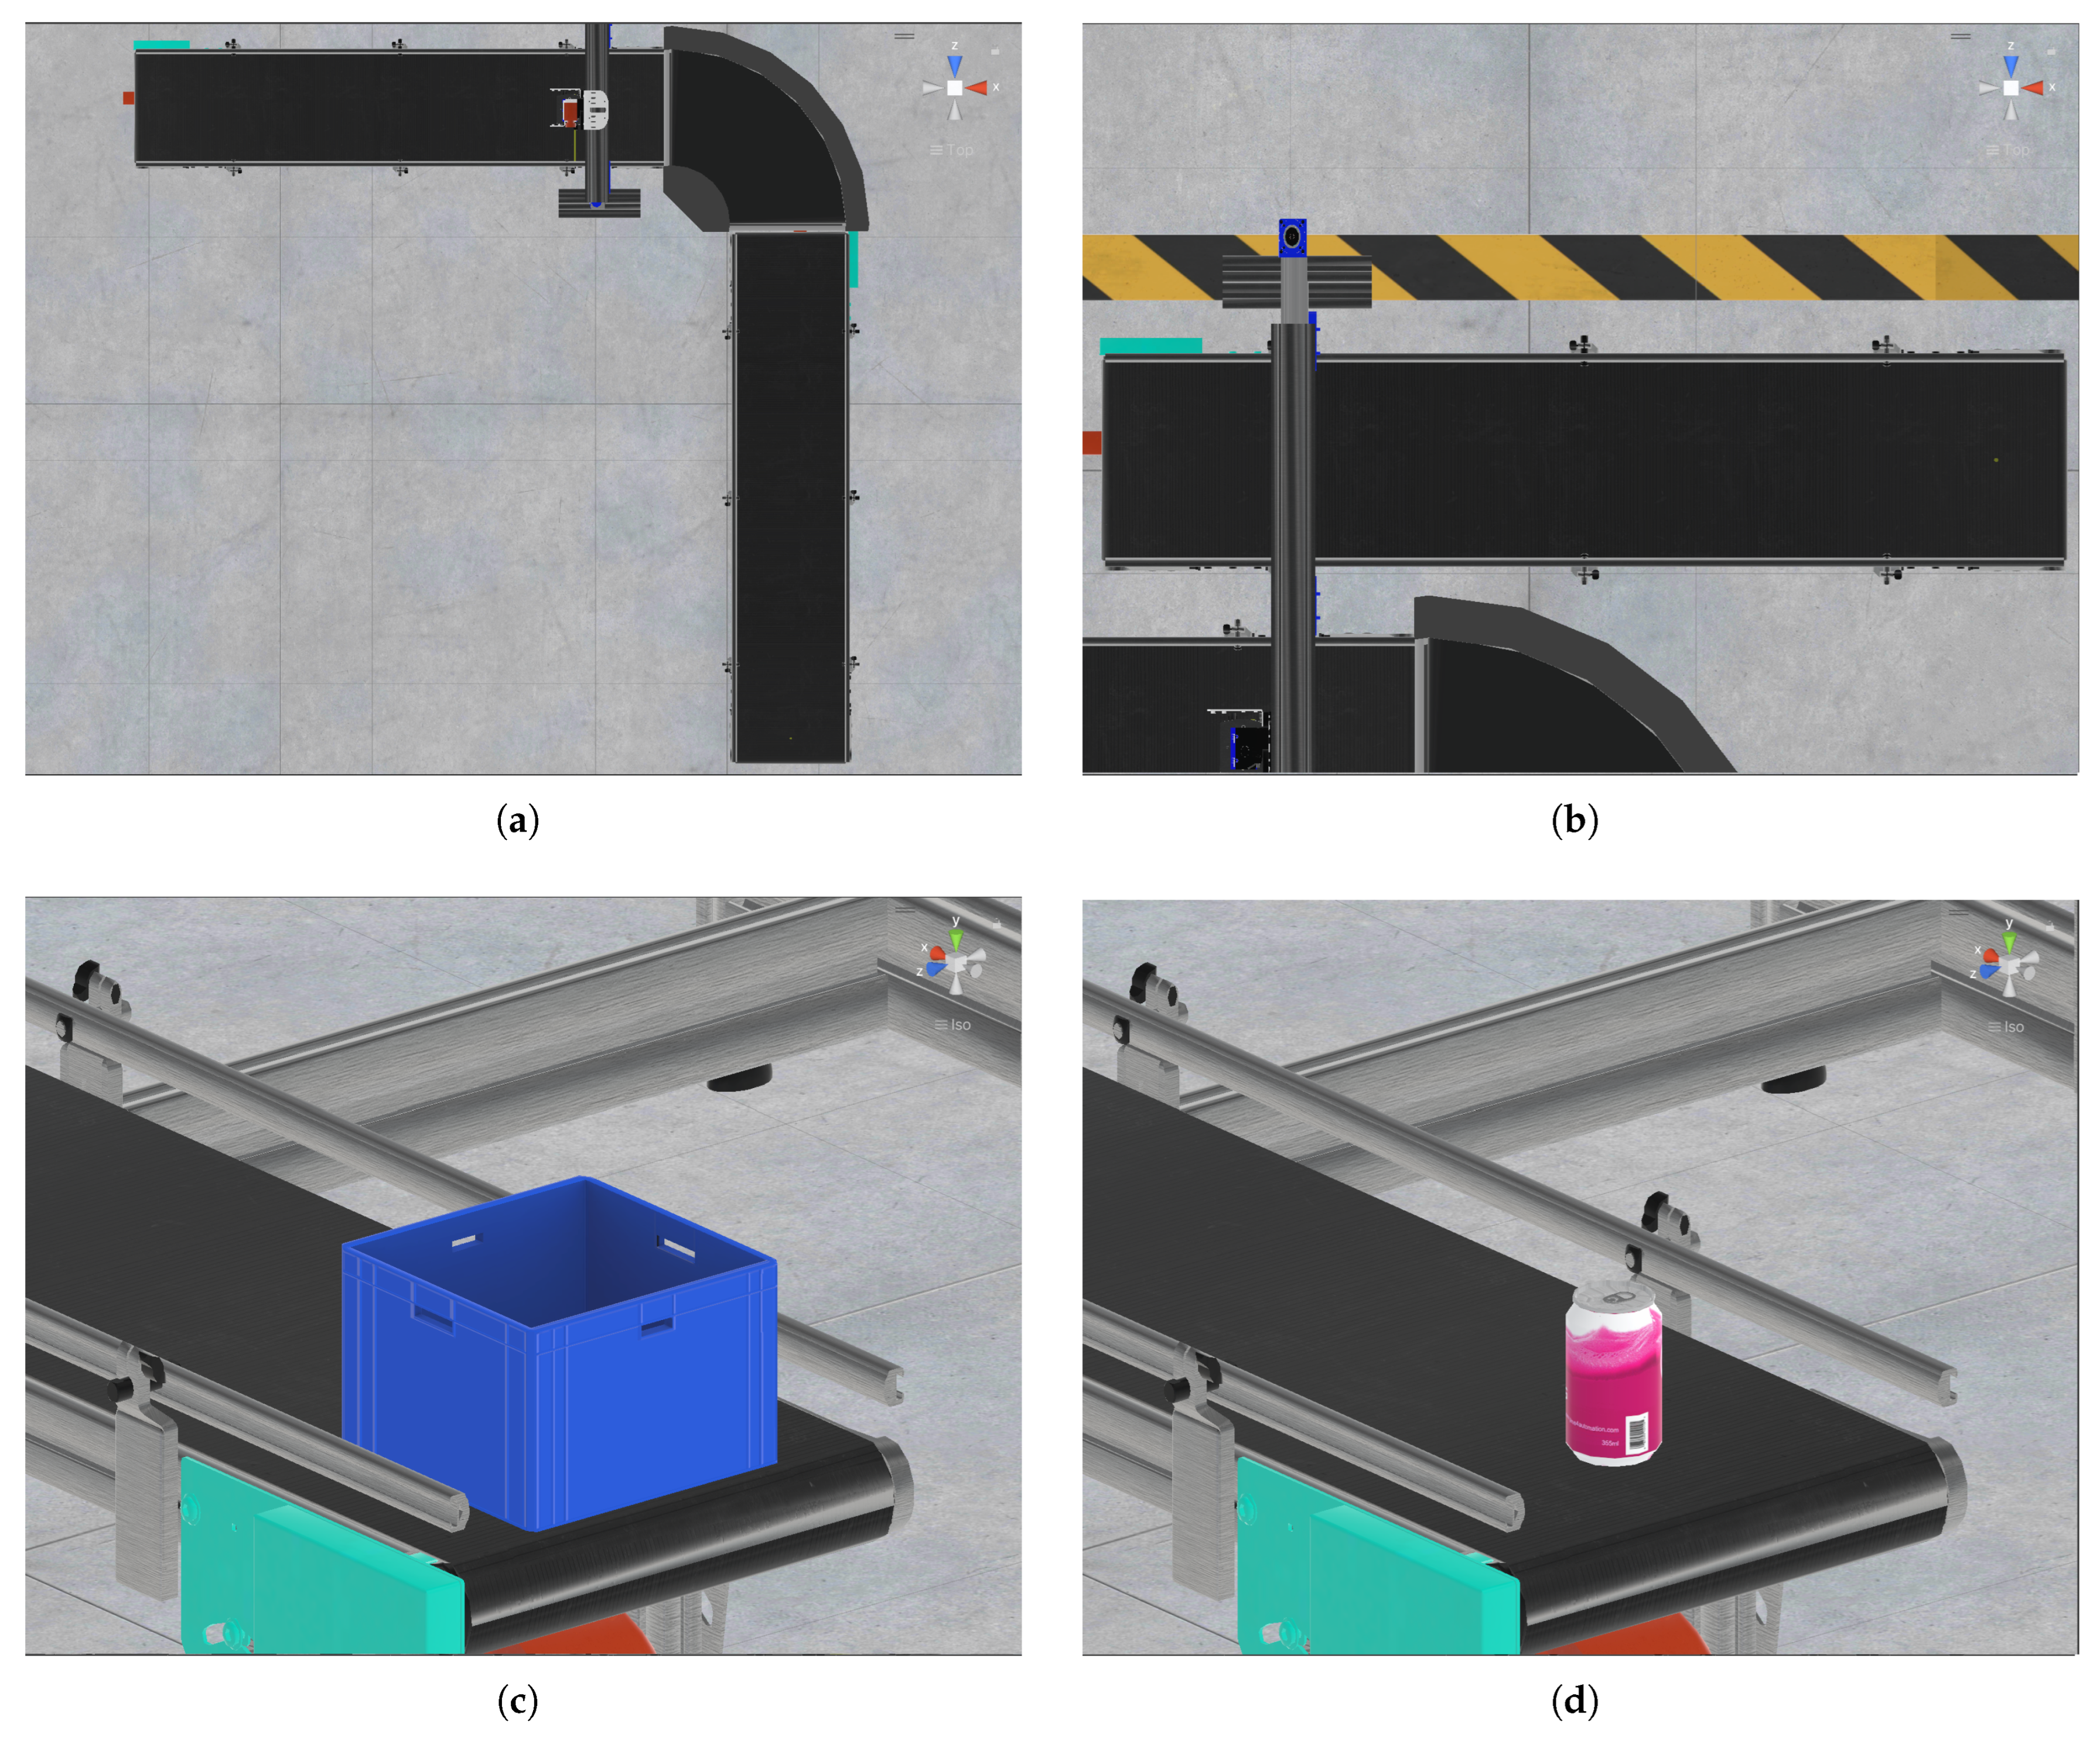
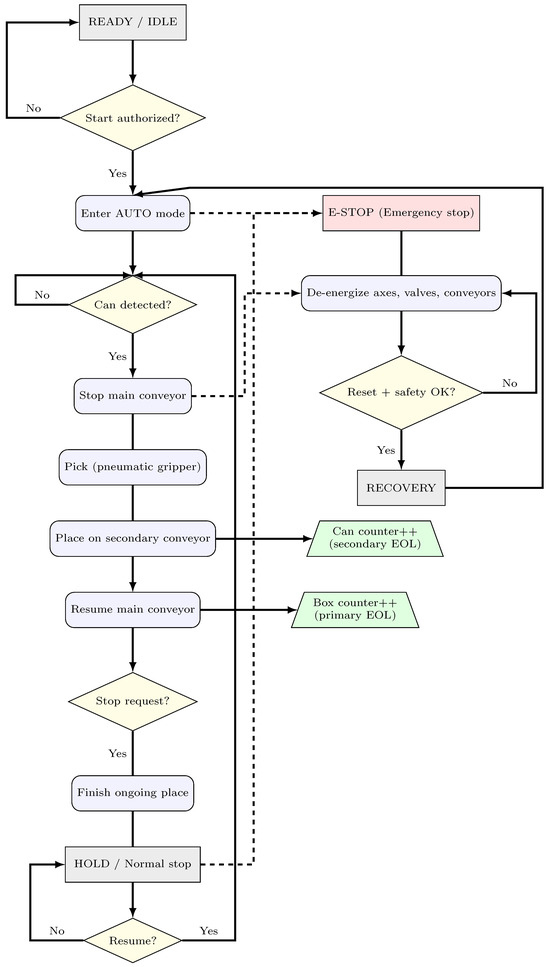
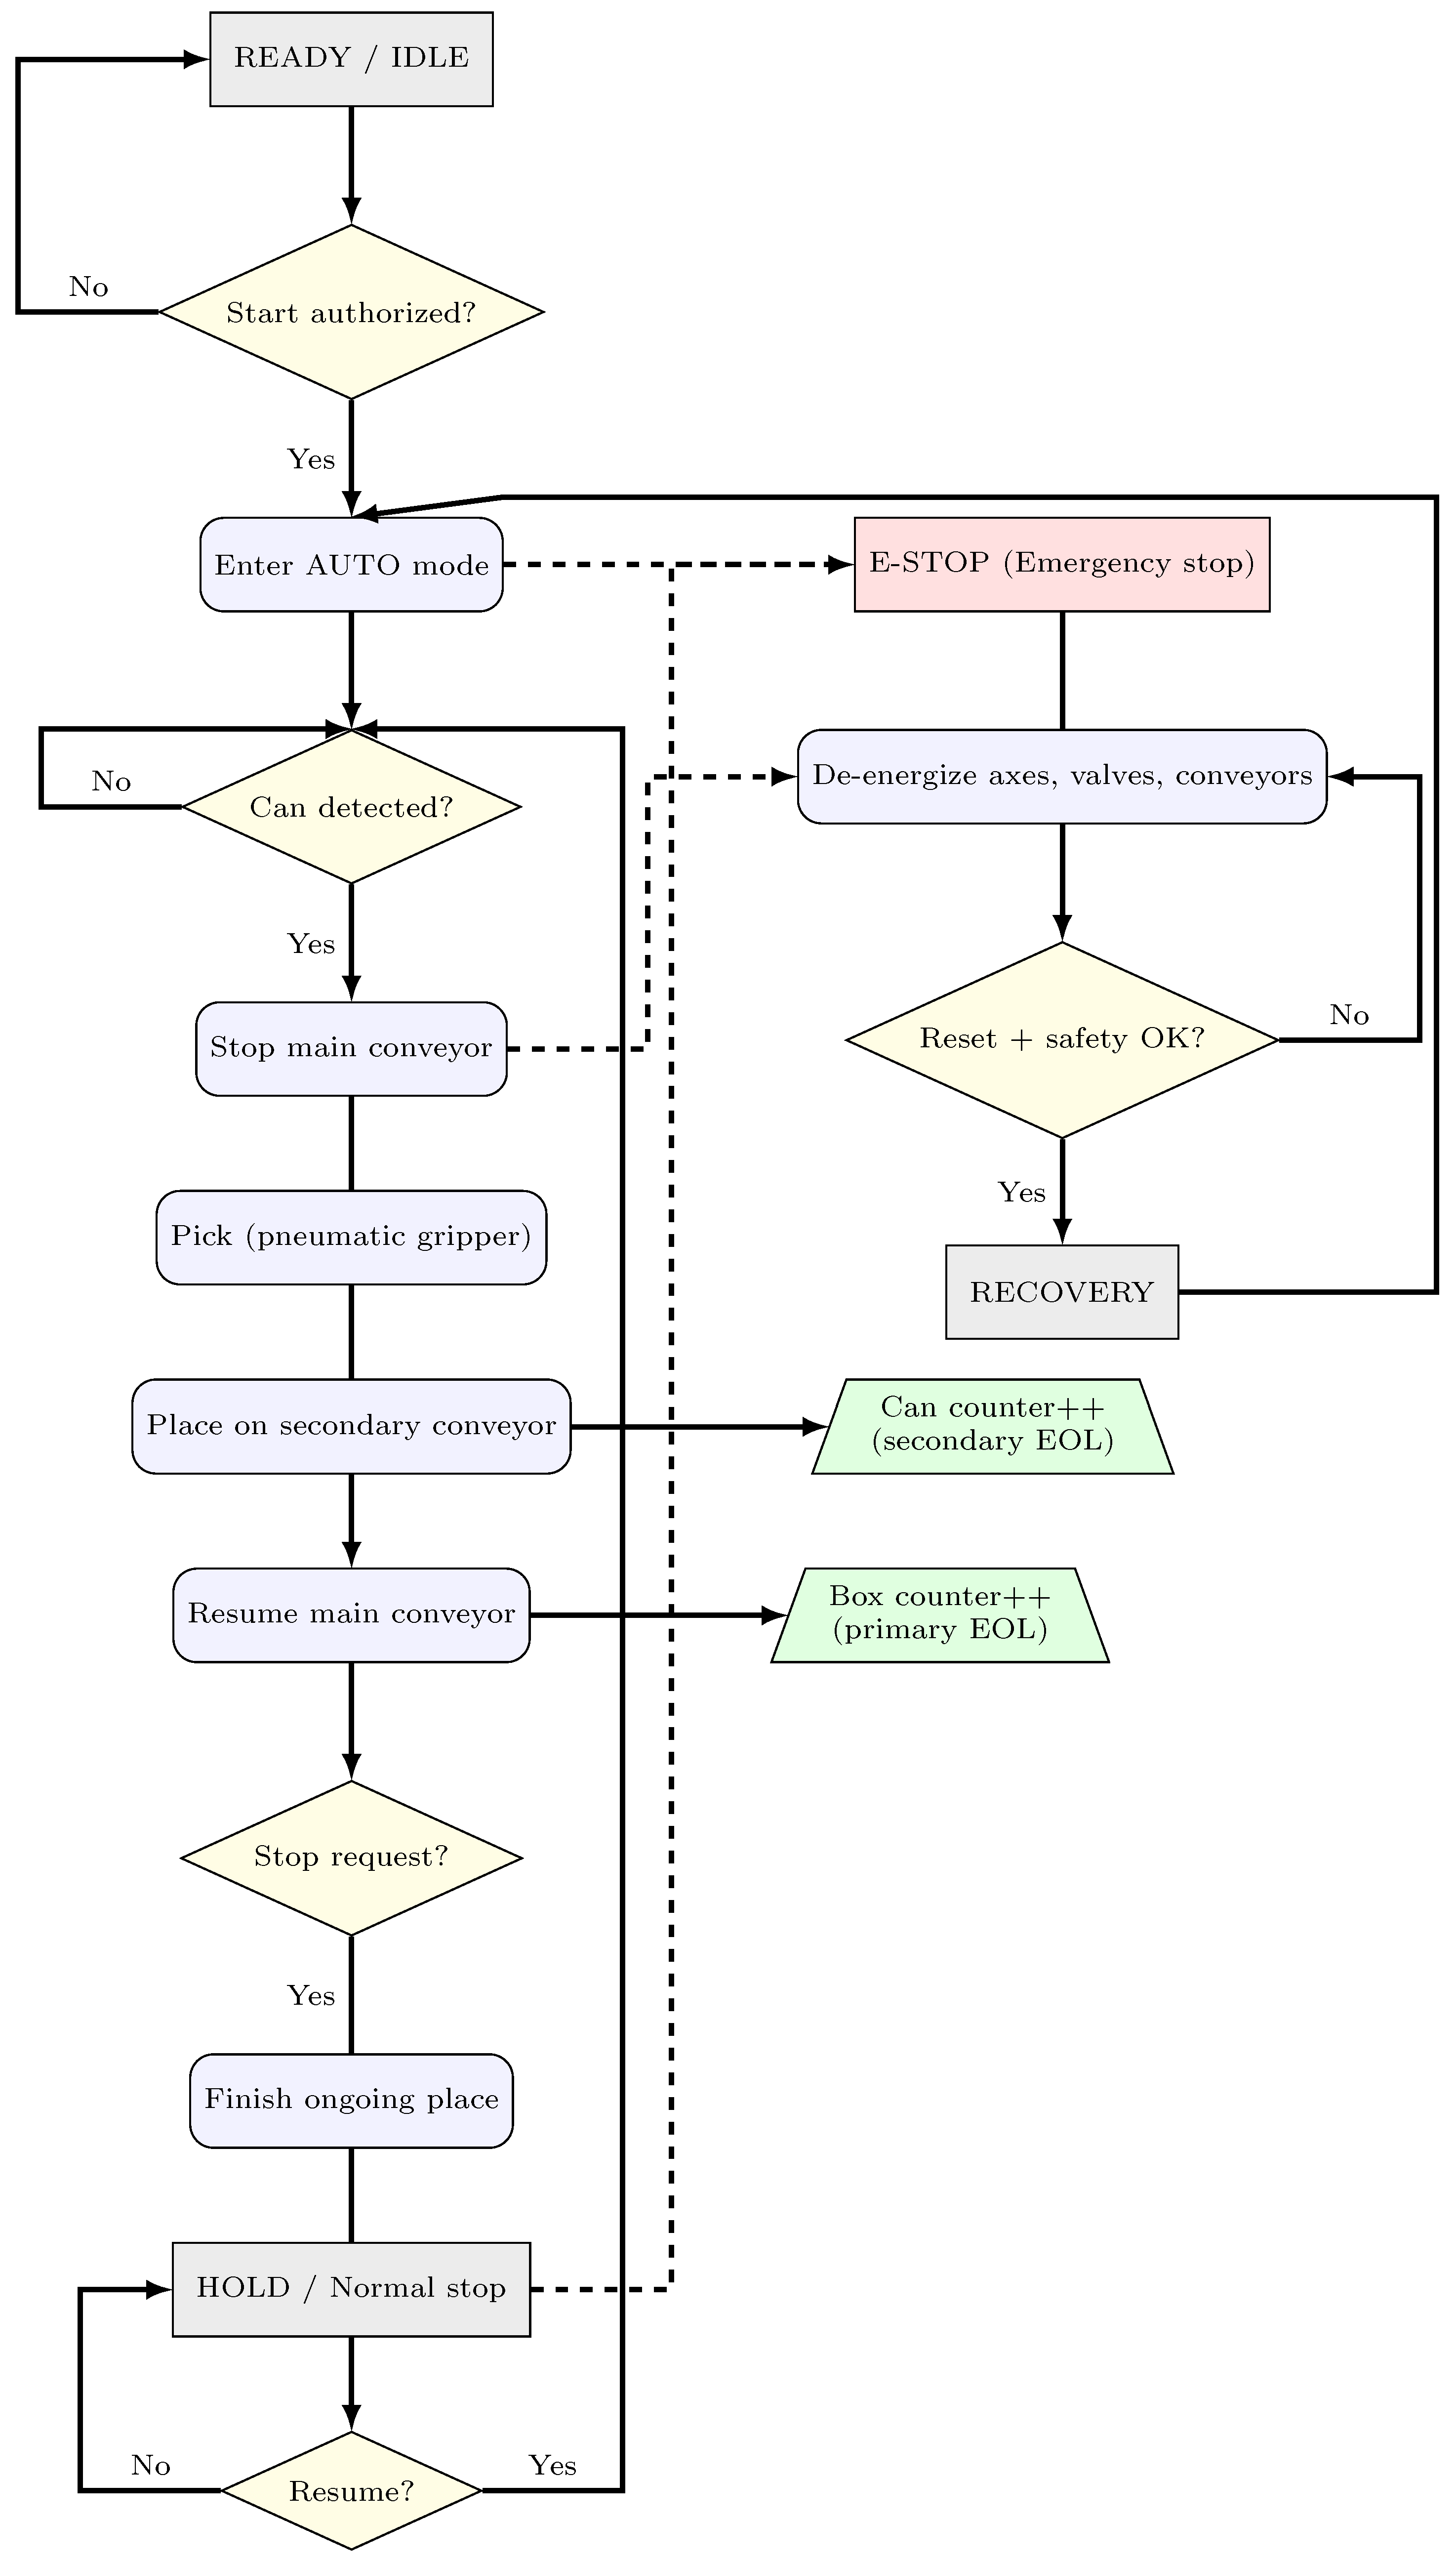
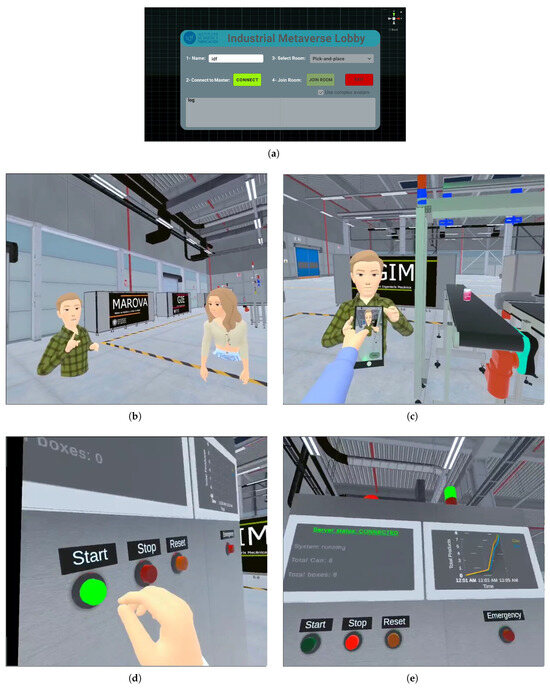
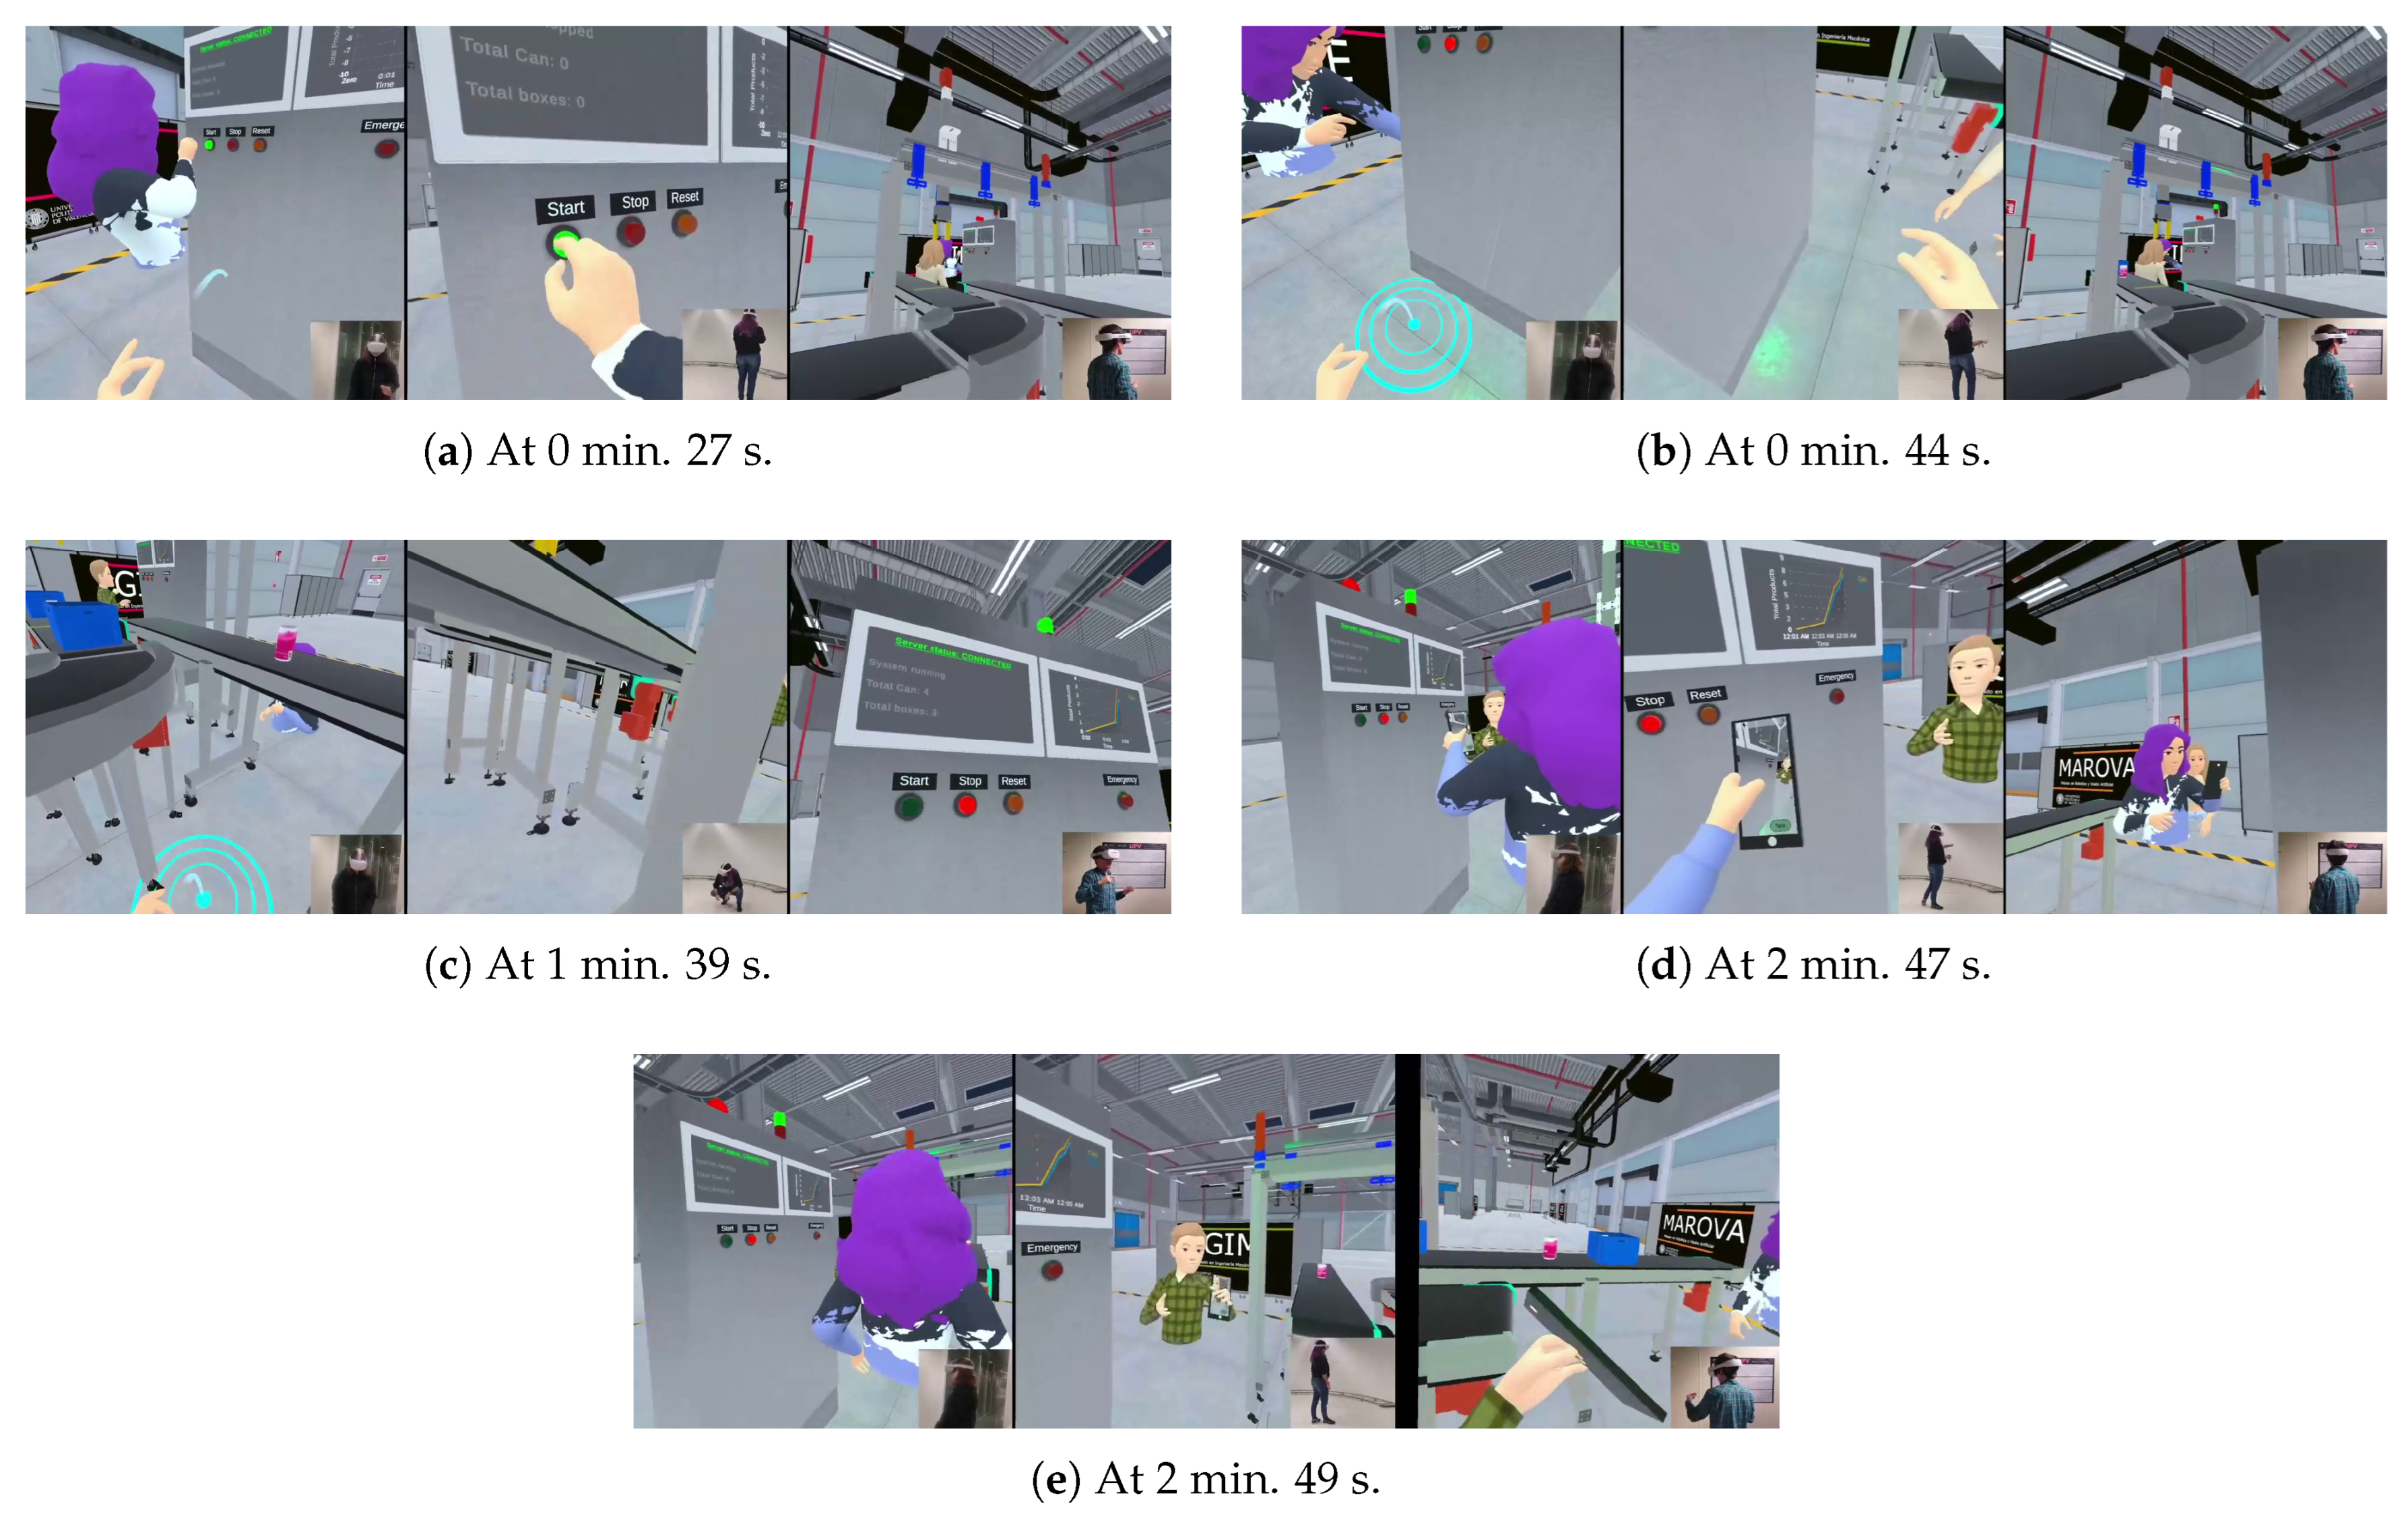
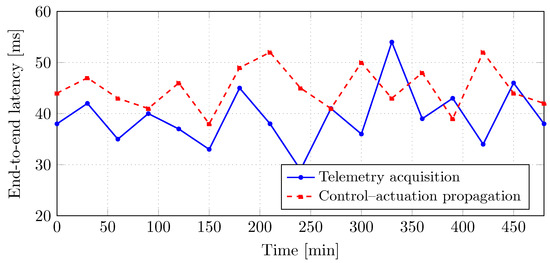
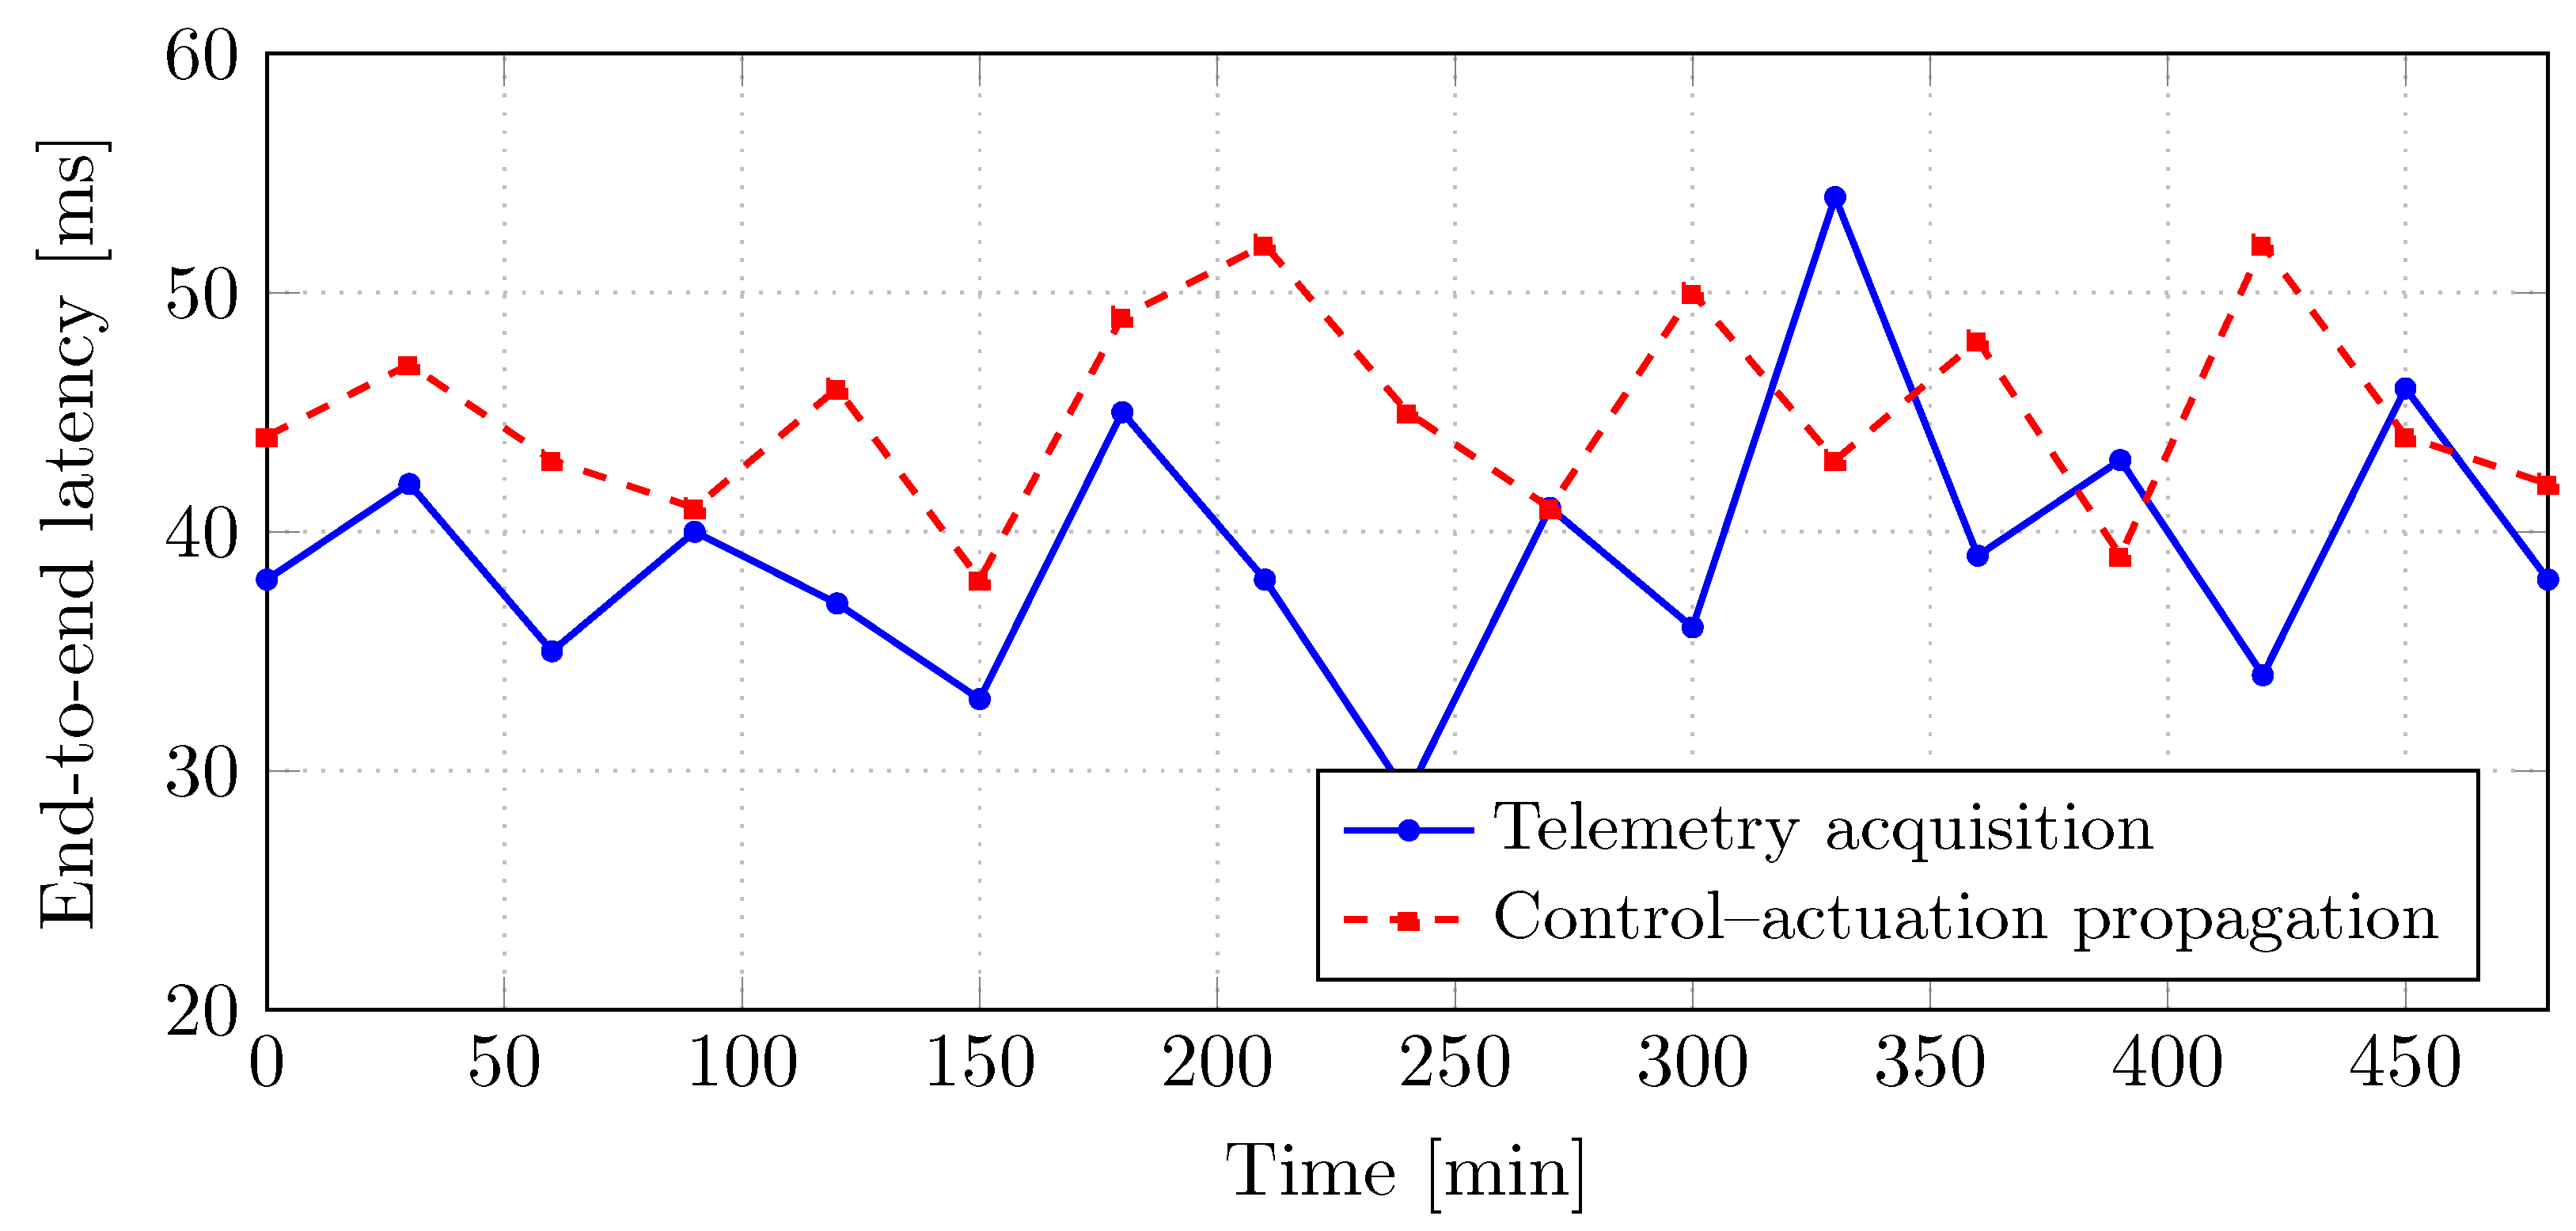
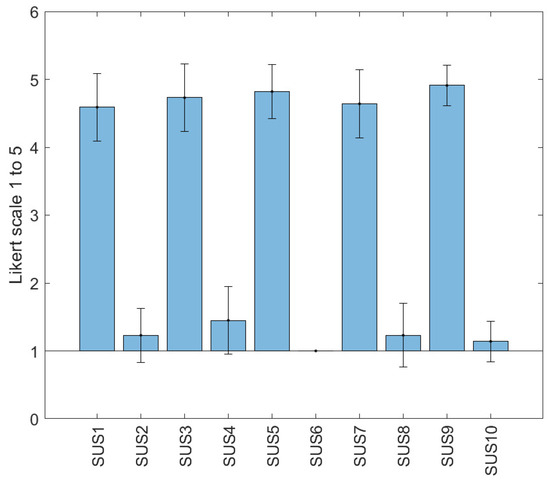
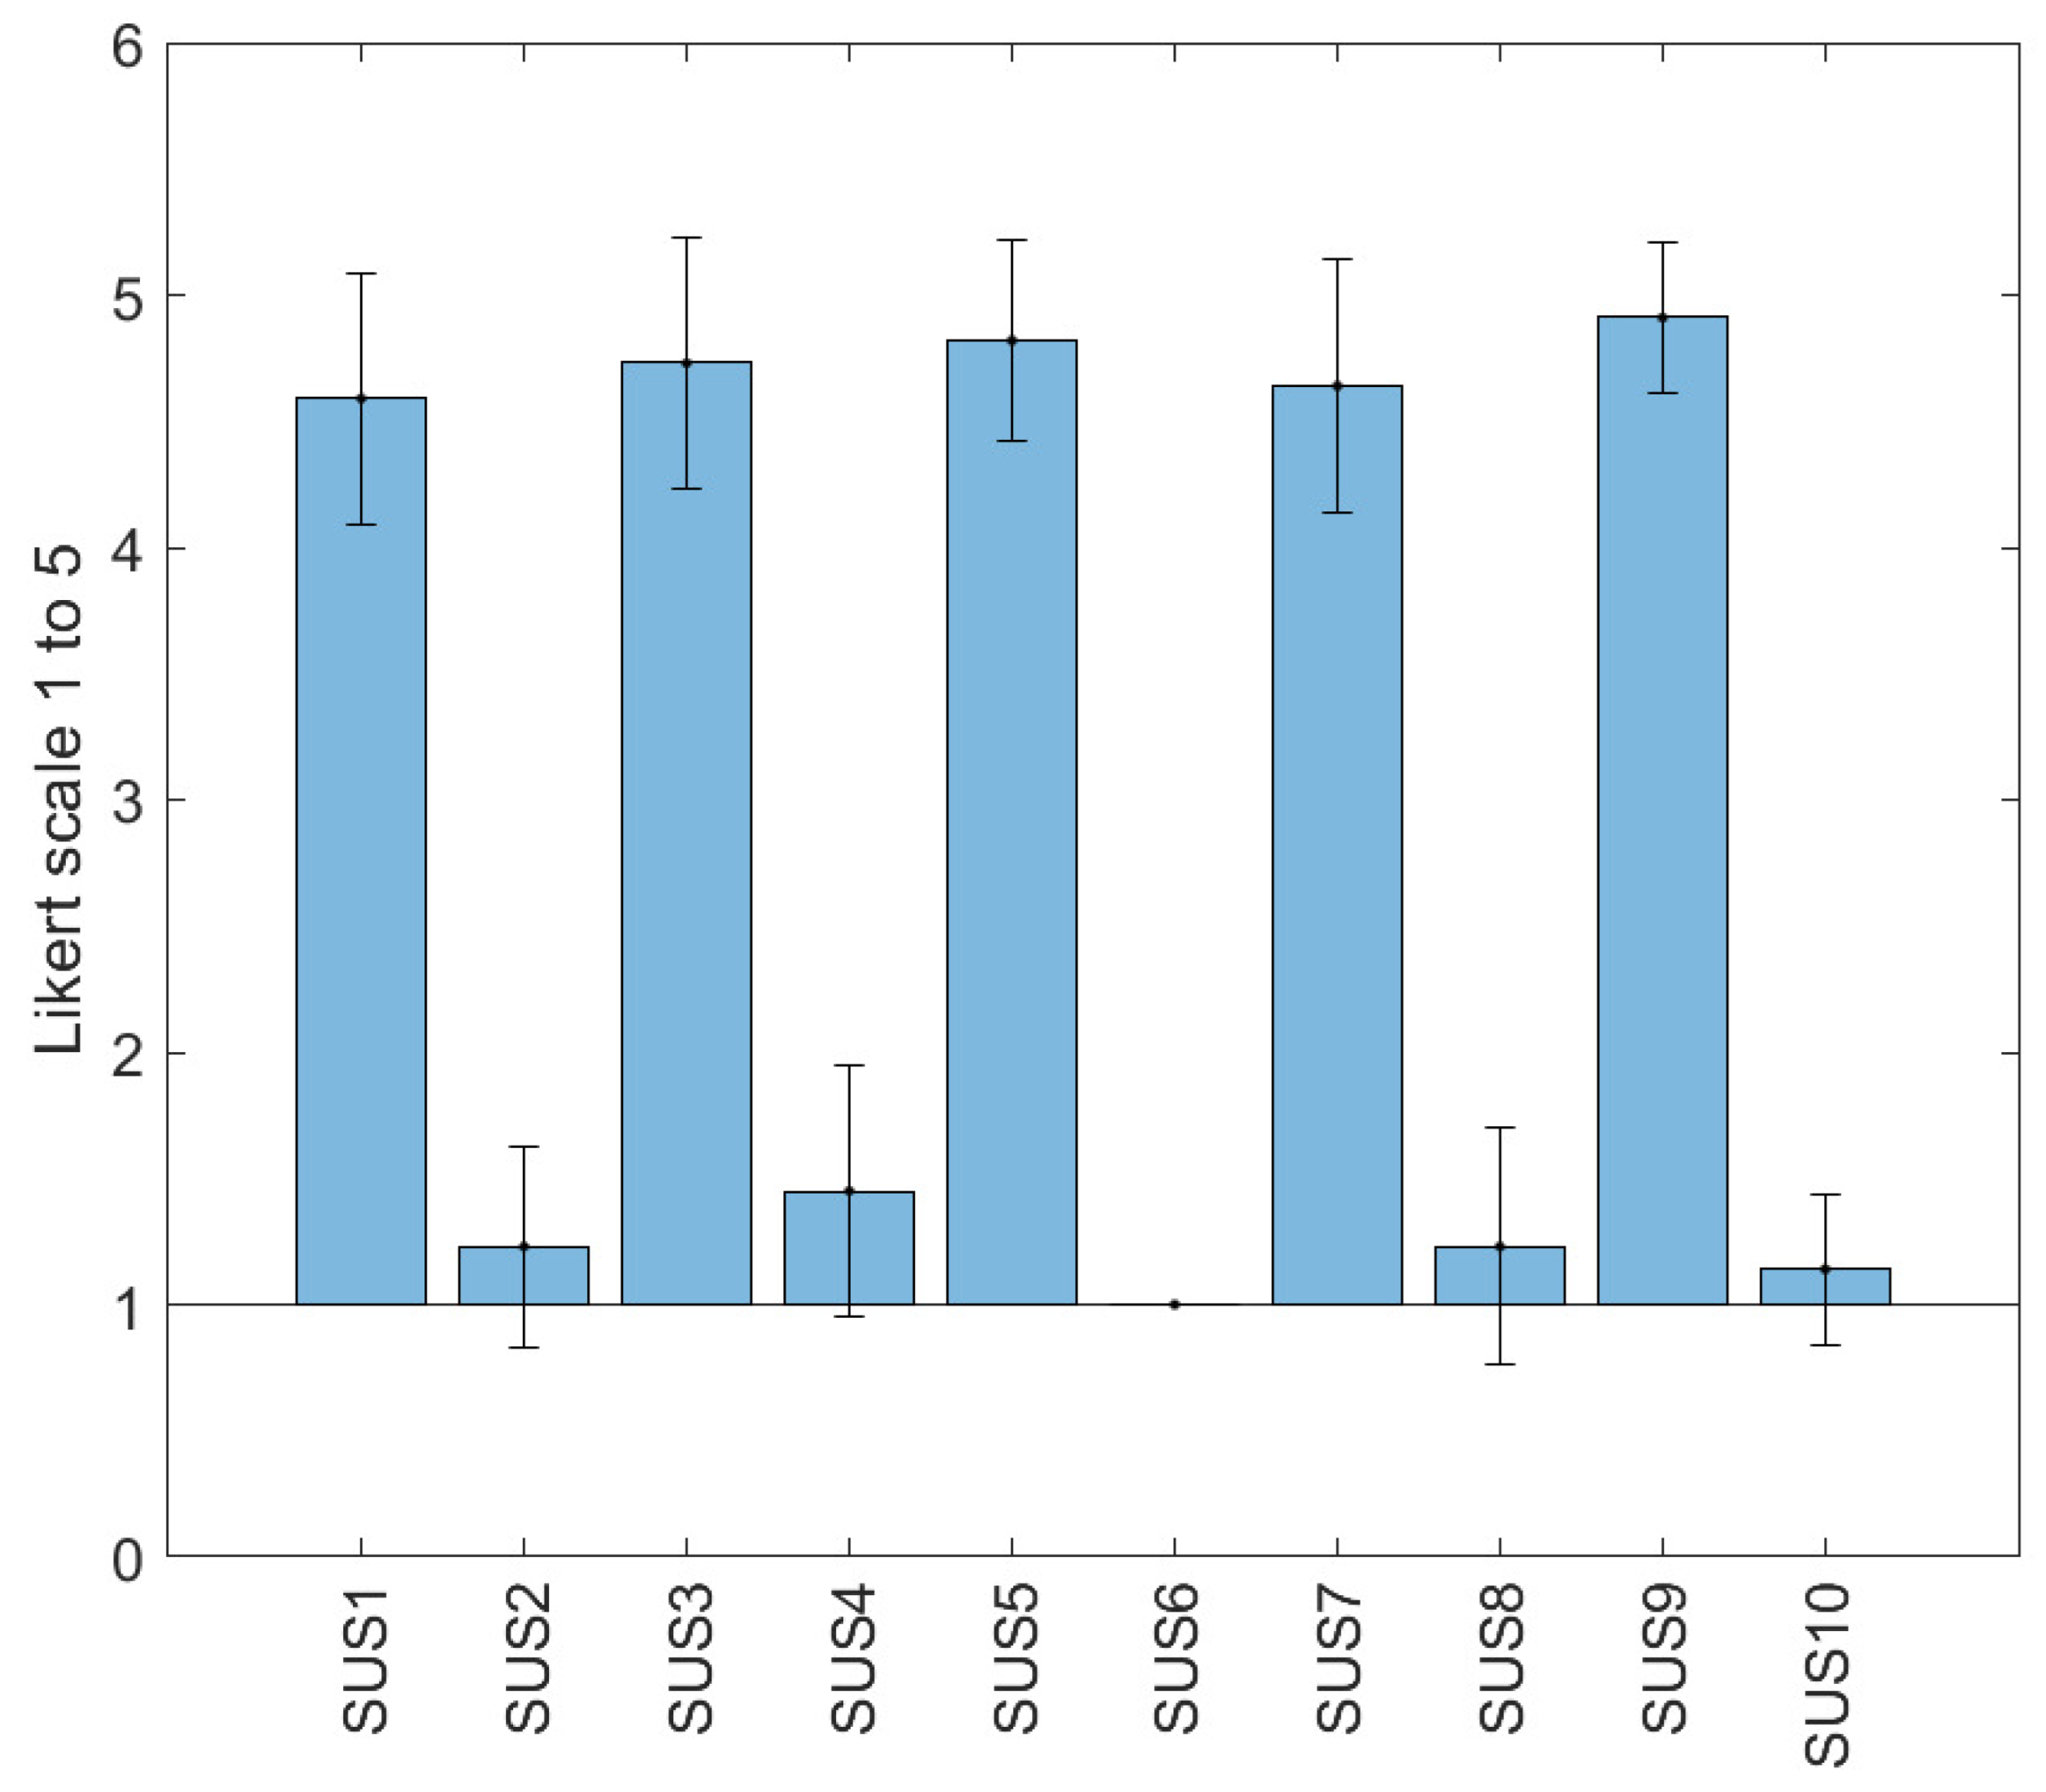
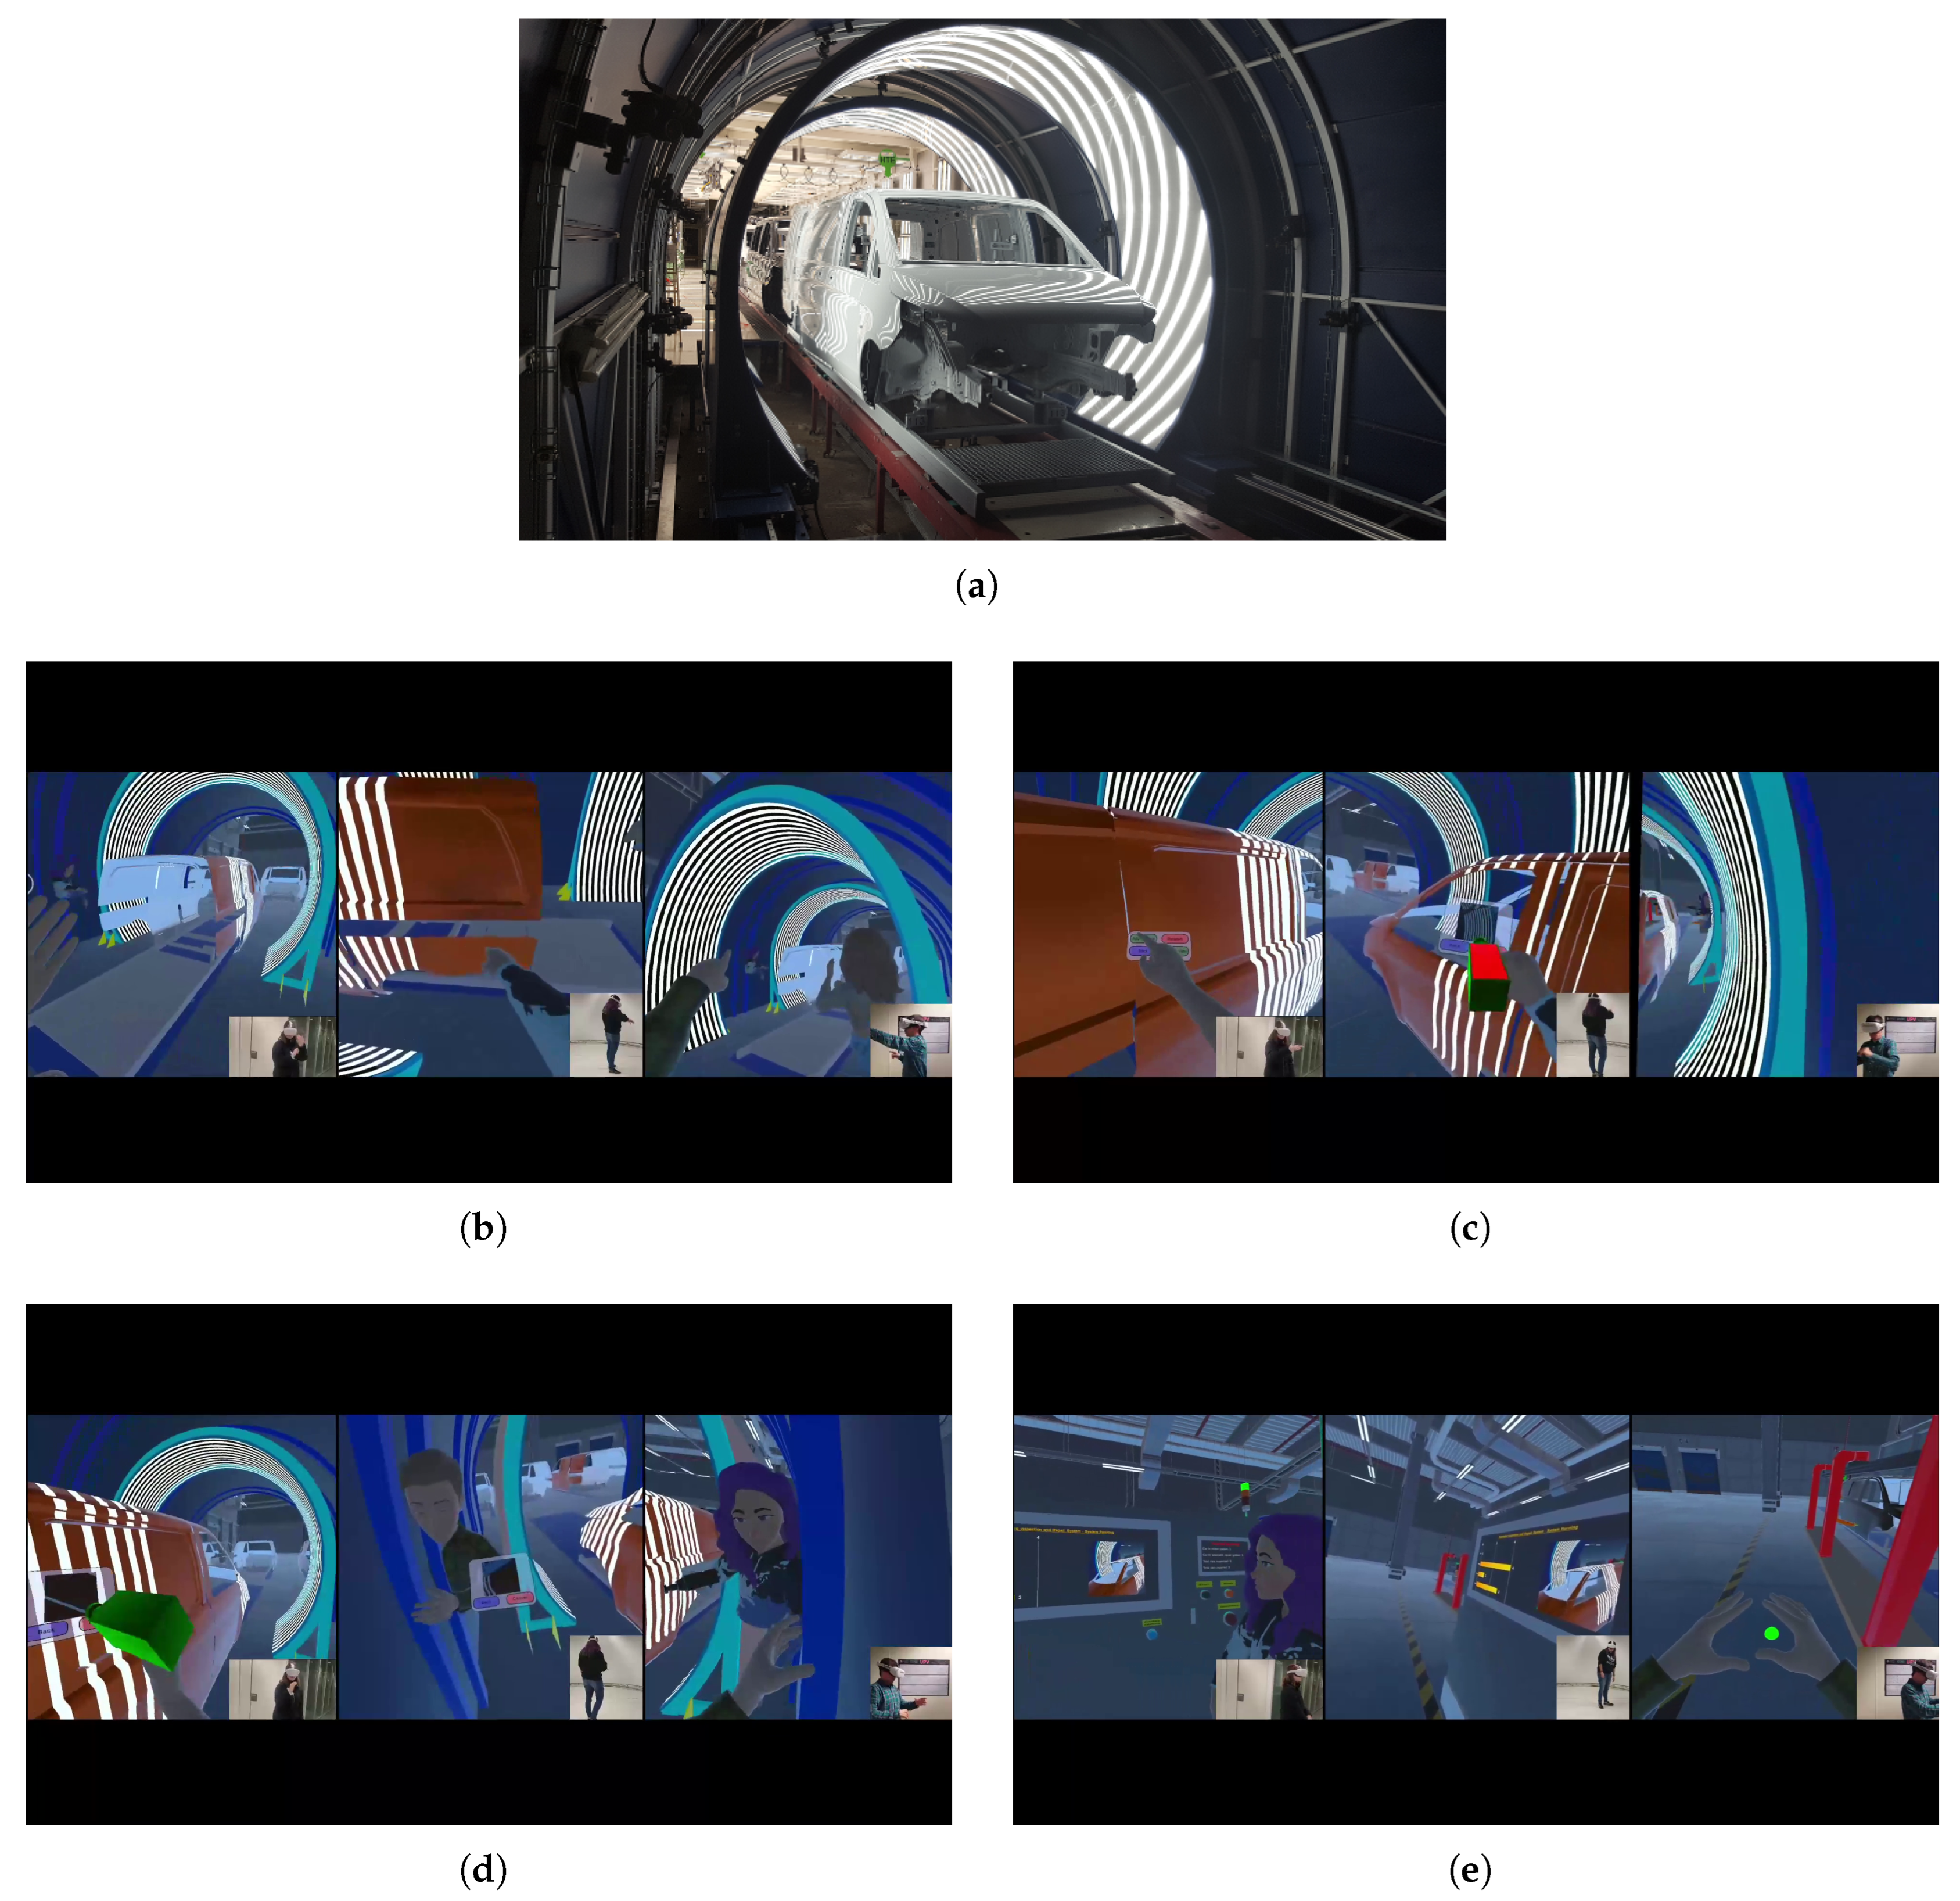

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.