


Abstract
This study addresses the power dispatching of a DC-coupled three-phase grid-connected photovoltaic (PV) and energy storage-integrated system by proposing a peak shaving and valley-filling control architecture based on time-of-use (TOU) pricing. This research involves achieving maximum power-point tracking (MPPT) for PVMAs using a boost converter combined with the perturb and observe (P&O) method. A lithium-iron phosphate battery pack is integrated into the DC link via a bidirectional buck-boost converter, where charging and discharging control is executed according to peak and off-peak periods to regulate and stabilize the DC link voltage. Furthermore, bidirectional power flow control for peak and off-peak electricity consumption is realized using hysteresis current control and sinusoidal pulse-width modulation (SPWM) technologies within a smart inverter. By integrating the aforementioned power control architecture, the grid system can store energy from the utility during off-peak hours and release the stored energy during peak hours to reduce the load demand on the utility side. Initially, a simulation environment was established using Matlab/Simulink (2024b version) software, followed by control verification of the proposed system on a physical platform. The simulation and experimental results confirm that the integrated control architecture can precisely control the system’s DC link voltage at 800 V and stabilize the grid-connected AC voltage at an effective value (RMS) of 380 V. Moreover, under conditions of peak/off-peak switching and load variations, the system effectively demonstrates its stability and efficacy in performing valley filling and peak shaving. The proposed strategy achieves a power factor above 0.99 and a total harmonic distortion (THD) below 5%, regulates the DC-link voltage at 800 V with a steady-state error within 1.75%, and prevents up to 66.4 kWh of over-contract energy consumption per day under a 35 kW contract capacity, thereby contributing to sustainable energy management and economic savings.
1. Introduction
As industrial prosperity continues to flourish, the demand for electricity has increased substantially. Concurrently, the extensive use of fossil fuels and the resulting large-scale carbon emissions have progressively exacerbated the greenhouse effect. The surge in power demand during summer peak periods imposes significant pressure on the dispatching operations of utility companies. If improper dispatching leads to the shutdown of generating units, it may cause disasters such as fires or explosions in industrial machinery, directly impacting economic stability and productivity. Given the growing global focus on warming issues, large-scale photovoltaic (PV) power generation systems—characterized by high efficiency and low pollution—have been widely deployed to balance environmental protection with the mitigation of residential and industrial power demands during peak hours. However, as the scale of grid-connected PV systems grows, the original load profile has evolved into the “duck curve” [1]. During noon hours, the massive influx of PV power causes a significant drop in net load demand, forming a pronounced valley. In the evening, the rapid decline in PV generation, combined with rising electricity demand, results in an extremely steep ramp-up slope in the load curve. This poses a risk of generator tripping if the units cannot sustain the load. In light of this, battery energy storage systems (BESSs) are employed in conjunction with the utility’s time-of-use (TOU) pricing for power dispatching to alleviate the pressure on the utility’s spinning reserve during peak periods. Recent advancements in energy management emphasize the integration of battery energy storage systems (BESSs) with time-of-use (TOU) pricing to mitigate the duck curve effect. For instance, peak shaving and duck curve mitigation strategies based on ramp rate limits have been proposed to enhance power quality in SPV-BES microgrids [2]. Furthermore, advanced control approaches such as model predictive control (MPC) [3], decision tree learning algorithms for vehicle-to-grid (V2G) management [4], and optimized charging algorithms [5] have been extensively explored in the recent literature.
To enhance grid stability under the influence of the duck curve, researchers have conducted numerous studies on PV systems, battery packs, and smart inverters in recent years [3,4,5,6]. The authors of [3] addressed the control and energy management of grid-connected PV systems with integrated storage using MPC. While it successfully managed battery charging/discharging and load supply based on state-of-charge (SOC) simulations, the reliance on a minimum cost function to control the voltage source inverter involves a high number of case considerations, leading to a heavy computational burden. Furthermore, the authors of [4] applied a decision tree learning algorithm to a grid-connected microgrid for V2G energy management. By considering load demand and price fluctuations, electric vehicles were used as mobile storage for peak shaving. However, this method requires that daily load profiles, renewable energy output, and user lifestyles be accounted for; the resulting data volume and controller complexity significantly increase system implementation costs. Recently, the authors of [5] introduced a novel optimized charging algorithm for storage systems, combining four charging methods under three SOC conditions to reduce charging time to under one hour. Although it used negative current pulses to mitigate lithium plating and extend battery life, the frequent switching between modes requires real-time temperature sensing and results in high switching frequencies. This imposes strict requirements on circuit design and component precision, thereby increasing hardware costs. Specifically, the authors of [6] focused on resolving the efficiency issues of traditional three-phase rectifiers by controlling switching elements to achieve higher voltages and implementing power factor correction (PFC). Although this approach addressed drawbacks such as non-sinusoidal phase currents, total harmonic distortion (THD), and phase shifts associated with uncontrolled rectifiers, there is still room for further reduction in THD.
Specifically, a comparative analysis between previously reported control methods and the proposed architecture is presented in Table 1. As indicated, existing methods exhibit distinct limitations. The MPC proposed in [3] involves a high number of case considerations due to the cost function, resulting in a heavy computational burden and relatively high controller complexity. The decision tree algorithm applied in [4] requires a massive amount of historical data and training effort, leading to high controller architecture complexity and moderate computational burden. Furthermore, the optimized charging method introduced in [5] relies on frequent switching modes and multi-mode operational logic, resulting in moderate controller complexity and increased hardware costs. Although the active rectifier in [6] effectively improves power factor correction (PFC), its THD performance still has room for improvement.
Table 1.
Comparison of existing control strategies and the proposed method.
Compared to the aforementioned references, the control architecture proposed in this study simplifies the design, thereby significantly reducing computational complexity and enhancing active power dispatch capability without increasing hardware costs. Unlike existing methods that either impose high computational burdens [3,4] or neglect over-contract penalties [5,6], the proposed strategy integrates all three objectives—low complexity, over-contract prevention, and seamless bidirectional dispatch—in a unified DC-coupled architecture.
To address the aforementioned literature gaps regarding TOU pricing integration, over-contract prevention, and computational burdens, this research proposes a low-complexity integrated active power dispatch strategy for a DC-coupled three-phase grid-connected solar PV and battery storage integrated system. The main scientific contributions are as follows: (1) implementing a simplified active power dispatch strategy that seamlessly combines peak shaving and valley filling; (2) integrating hysteresis current control into the proposed dispatch framework to achieve seamless bidirectional power flow and high-power-factor operation without requiring additional hardware; and (3) realizing an anti-over-contract-capacity protection and smart charging strategy that balances battery lifespan with maximum economic benefits.
2. Peak Shaving and Valley-Filling Control Technology
Peak shaving and valley filling [7] is a power-dispatching strategy which mitigates the “duck curve” effect in power demand caused by variations in PV power generation. By utilizing the electricity price differential between peak and off-peak periods, this strategy encourages consumers to store electricity in energy storage systems (ESSs) during off-peak intervals. During peak demand periods, the energy stored during off-peak hours is released as an auxiliary power supply to achieve the goals of shaving peak loads and filling off-peak valleys, thereby smoothing out the load demand. Furthermore, this strategy alleviates the transmission load on the grid during peak hours, fundamentally reducing potential transmission power losses. To implement this dispatching strategy, it is essential to integrate PV and ESS using appropriate control architectures tailored to various power demands and operational modes.
2.1. Control Circuit Design of the Proposed Grid-Connected PV-Battery System
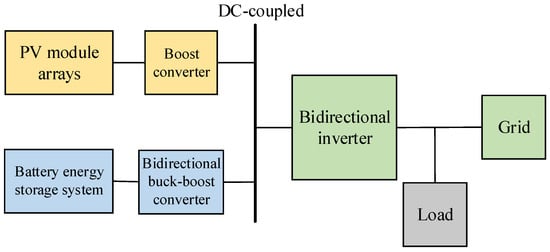
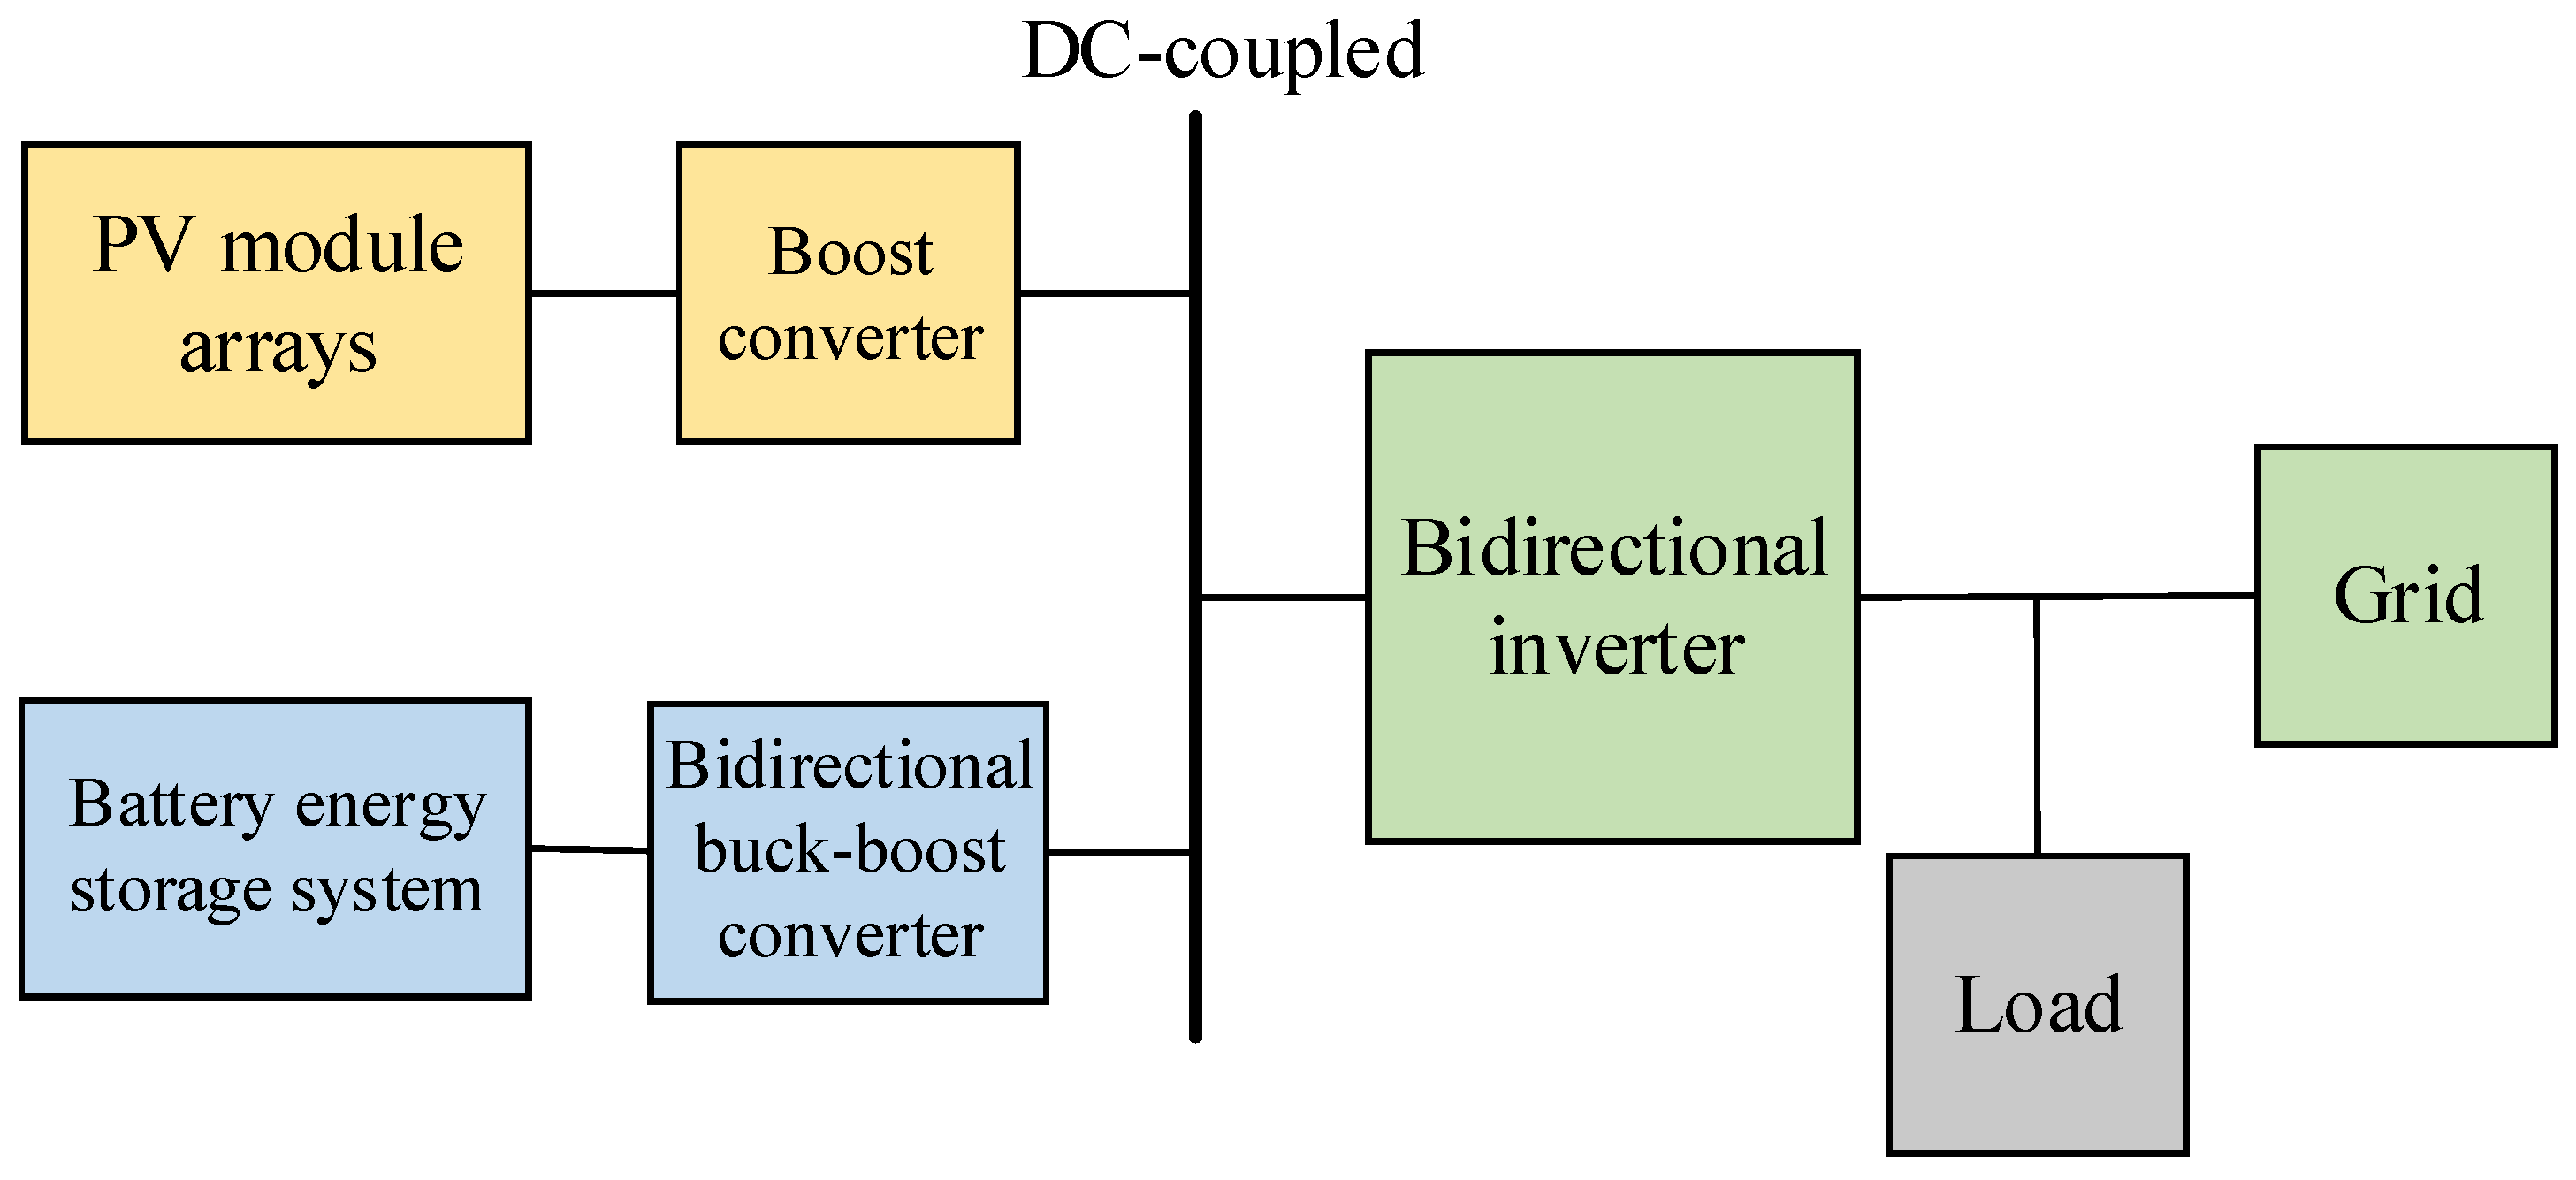
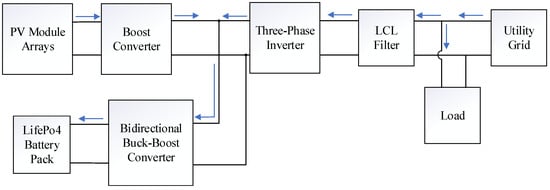
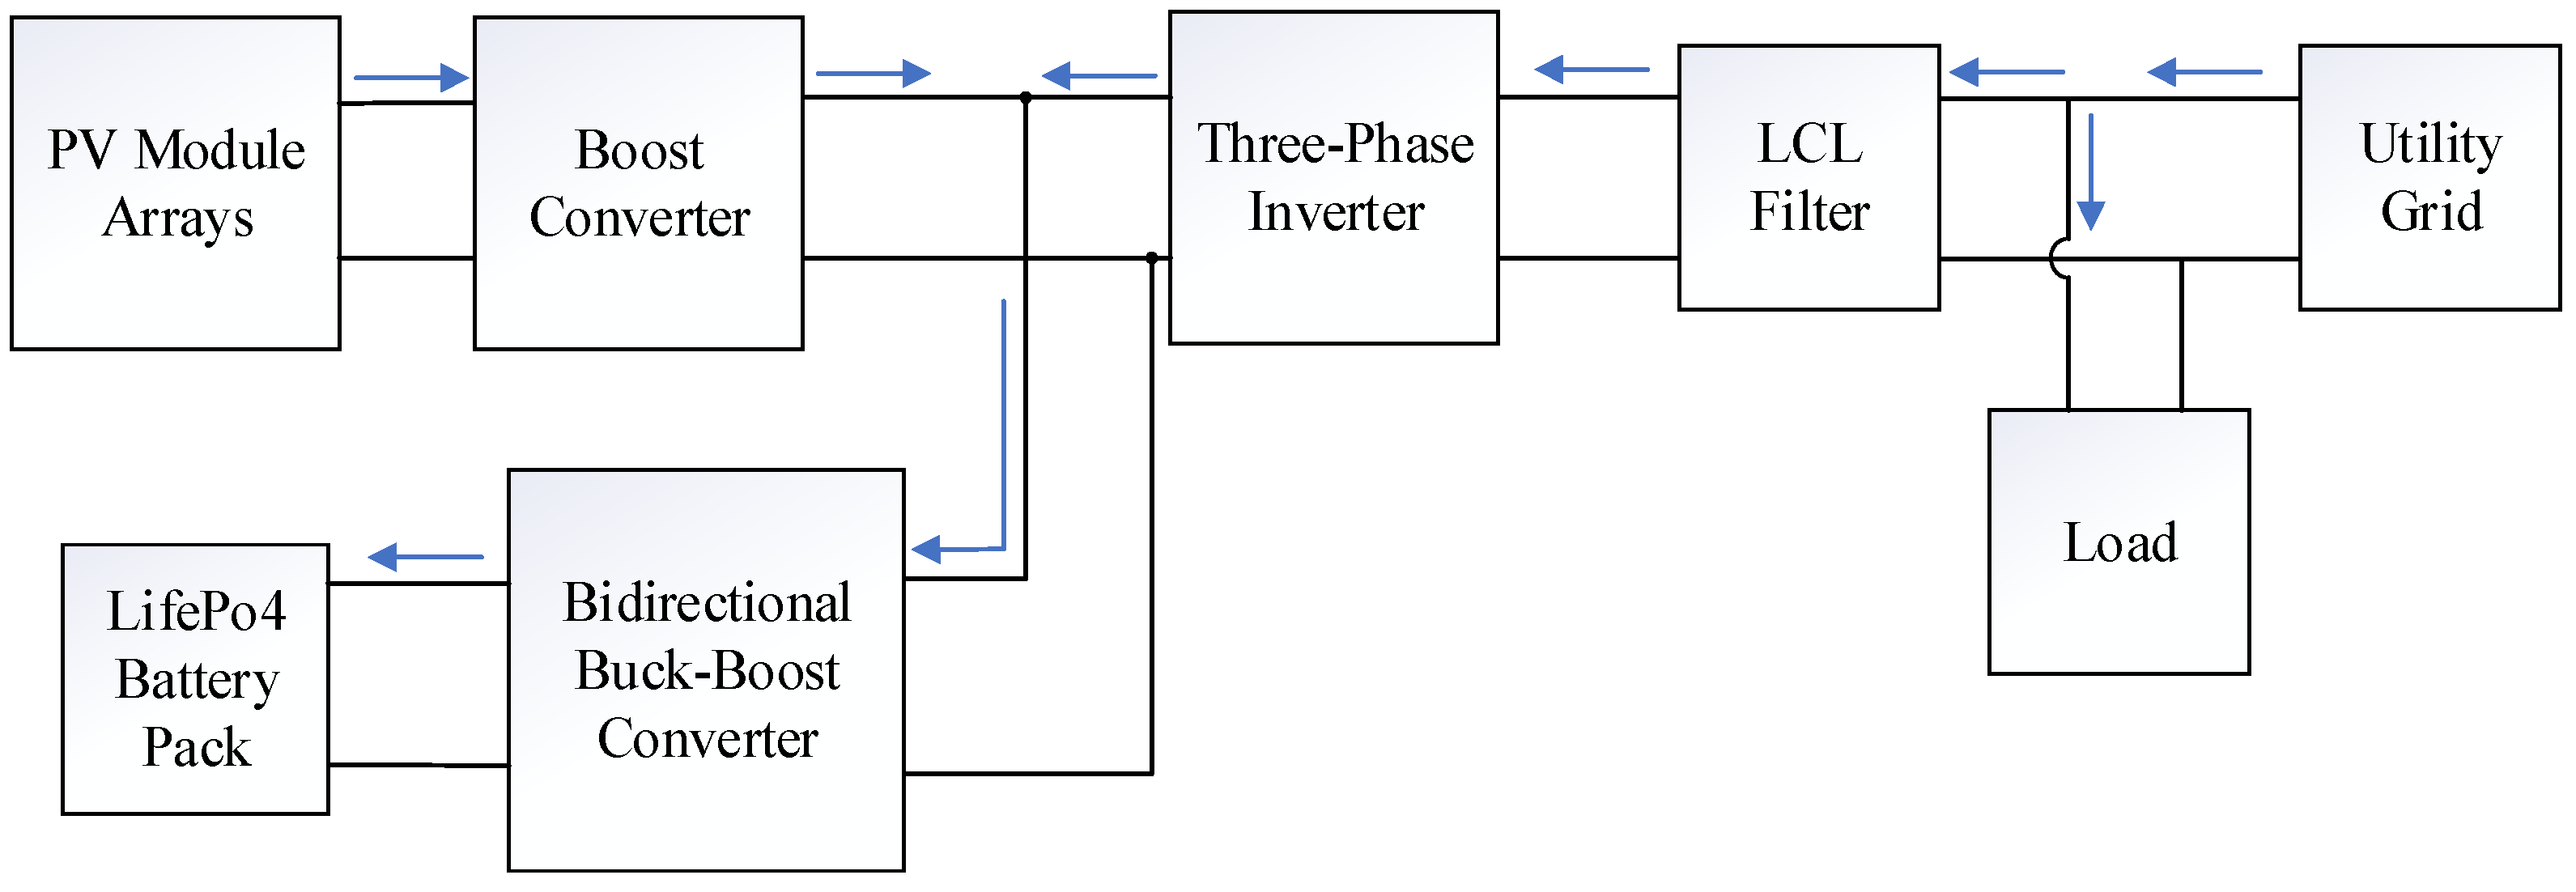
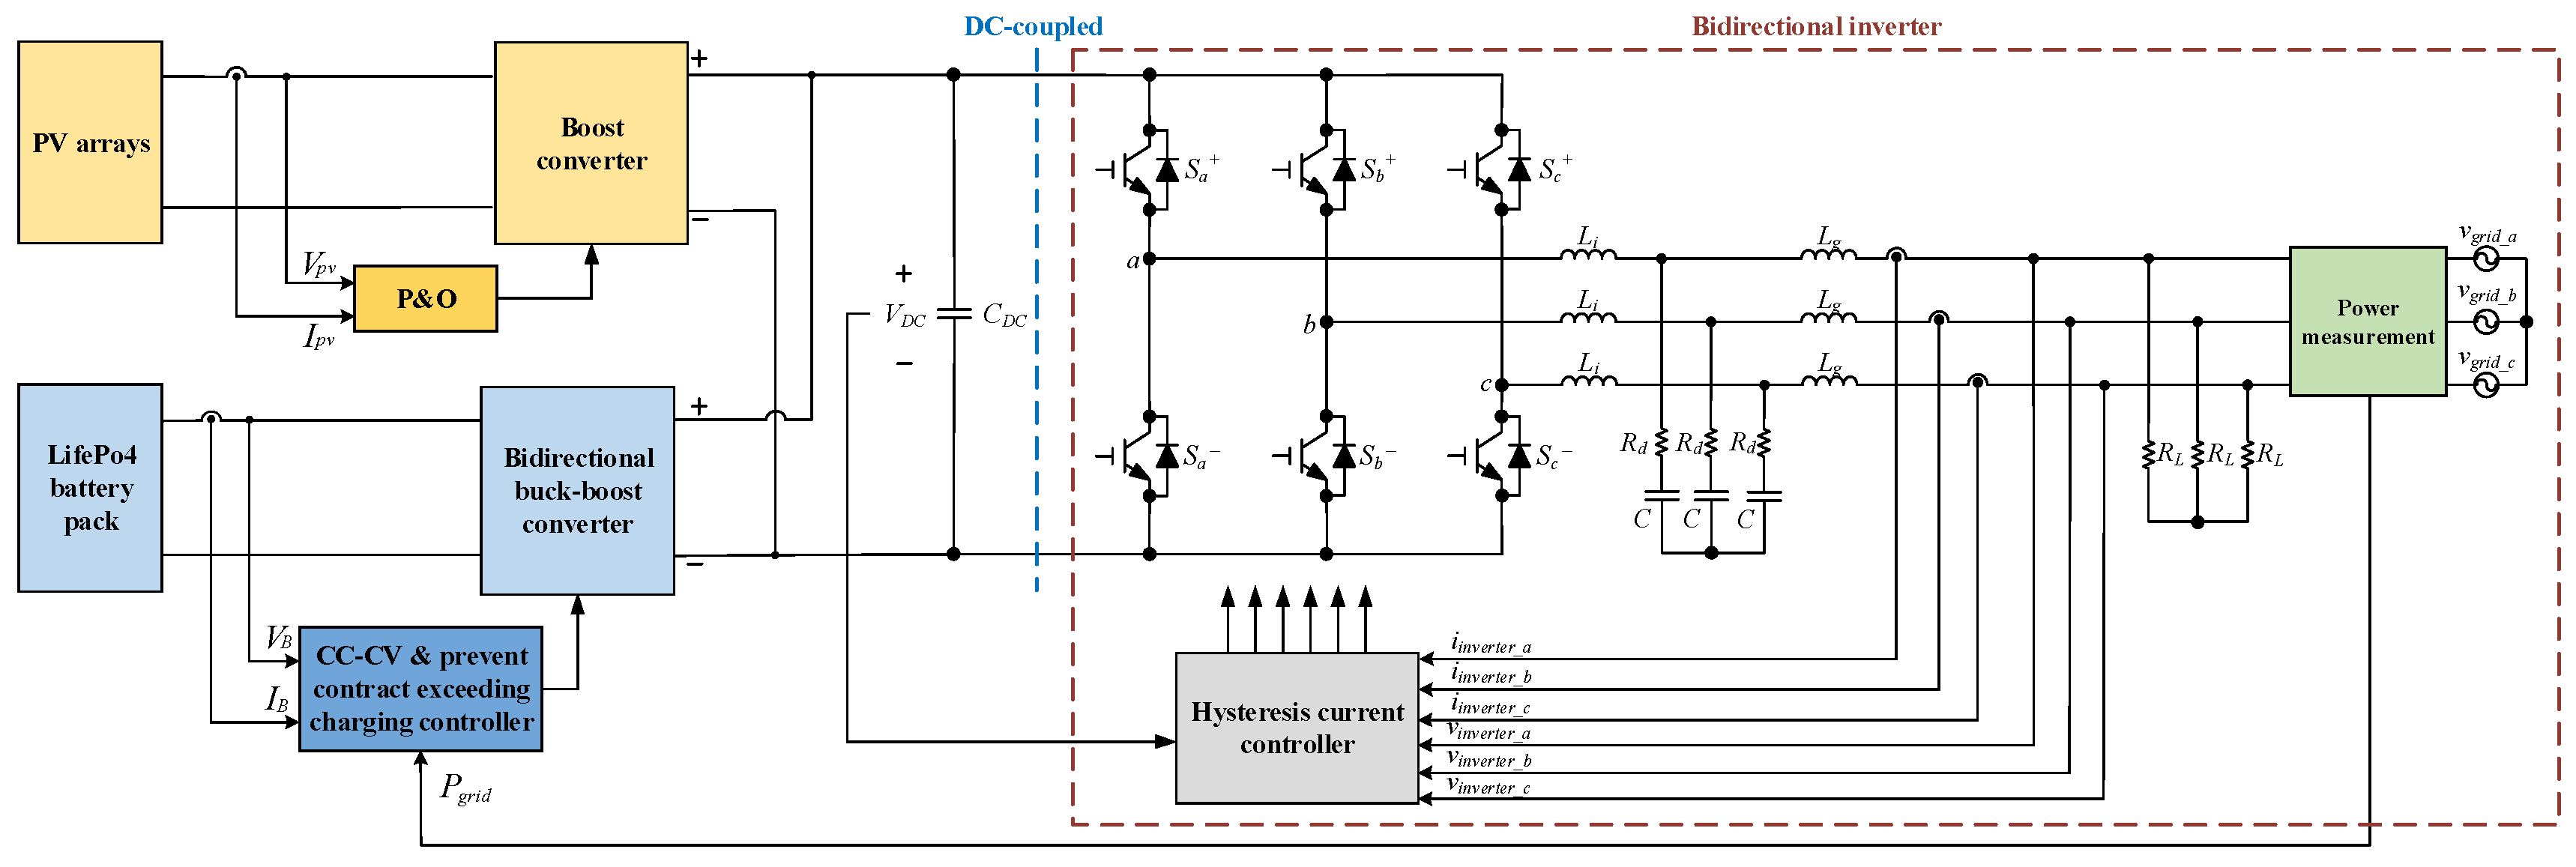
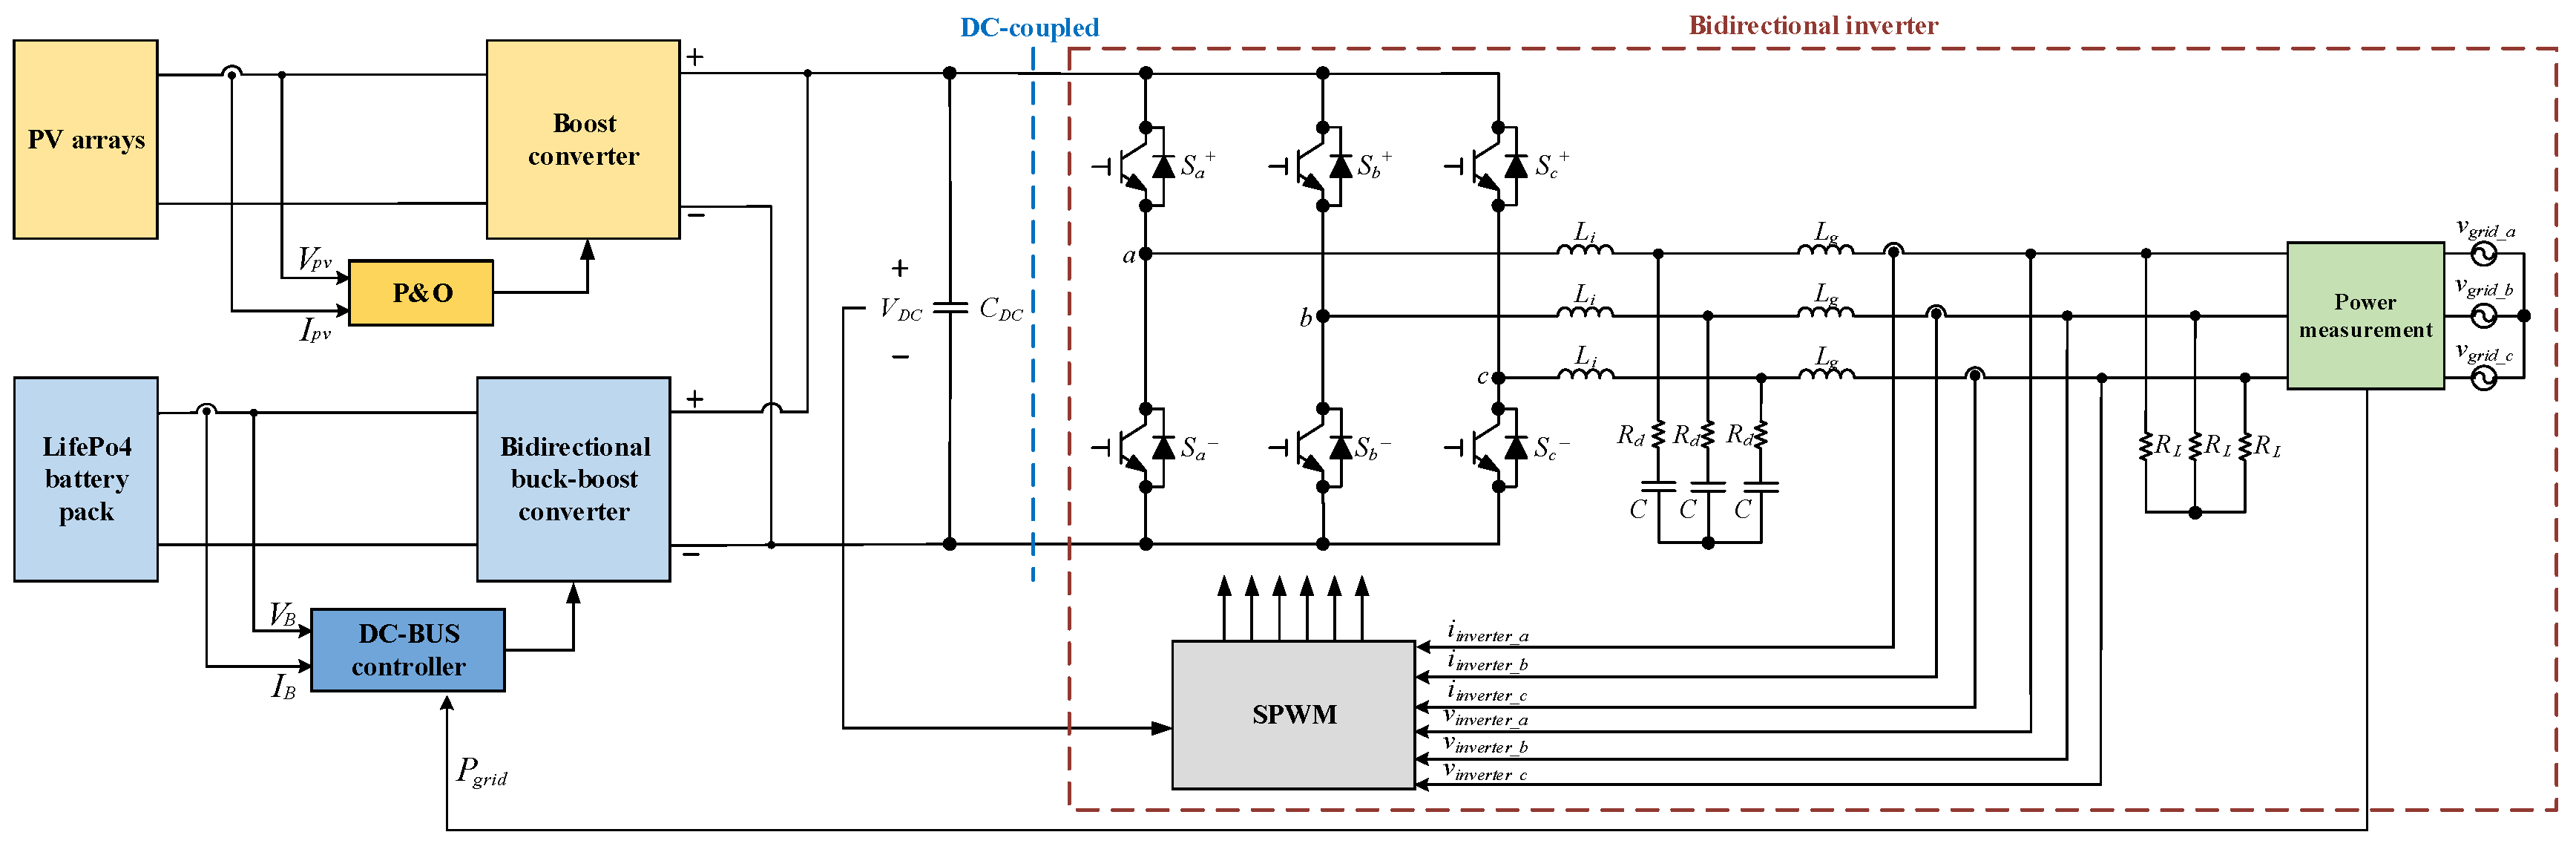
This study adopts a DC-coupled grid-connected power system [8], the overall architecture of which is illustrated in Figure 1. By connecting the PVMAs and the lithium-iron phosphate battery pack to the DC link through a boost converter and a bidirectional buck-boost converter, respectively, the system can directly store the DC power generated by the PV modules into the battery pack. This architecture effectively avoids the energy losses associated with multi-stage AC-DC conversions, thereby enhancing the energy conversion efficiency and cost-effectiveness of the power system. The detailed electrical specifications for the boost converter [9], bidirectional buck-boost converter [10], and three-phase smart inverter [11,12] utilized in the system are summarized in Table 2, Table 3, and Table 4, respectively. These selected specifications, including the 800 V DC-link voltage, 380 Vrms AC voltage, and 15 kHz switching frequency, are highly representative of typical industrial three-phase grid standards and the rated capacities of HIL testing platforms.
Figure 1.
Architecture diagram of the DC-coupled system.
Table 2.
Electrical specifications of the boost converter.
Table 3.
Electrical specifications of the bidirectional buck-boost converter.
Table 4.
Electrical specifications of the three-phase smart inverter.
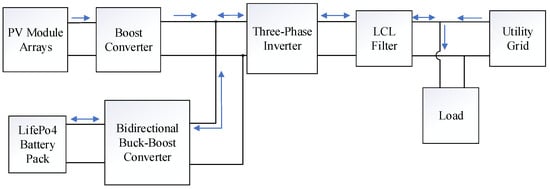
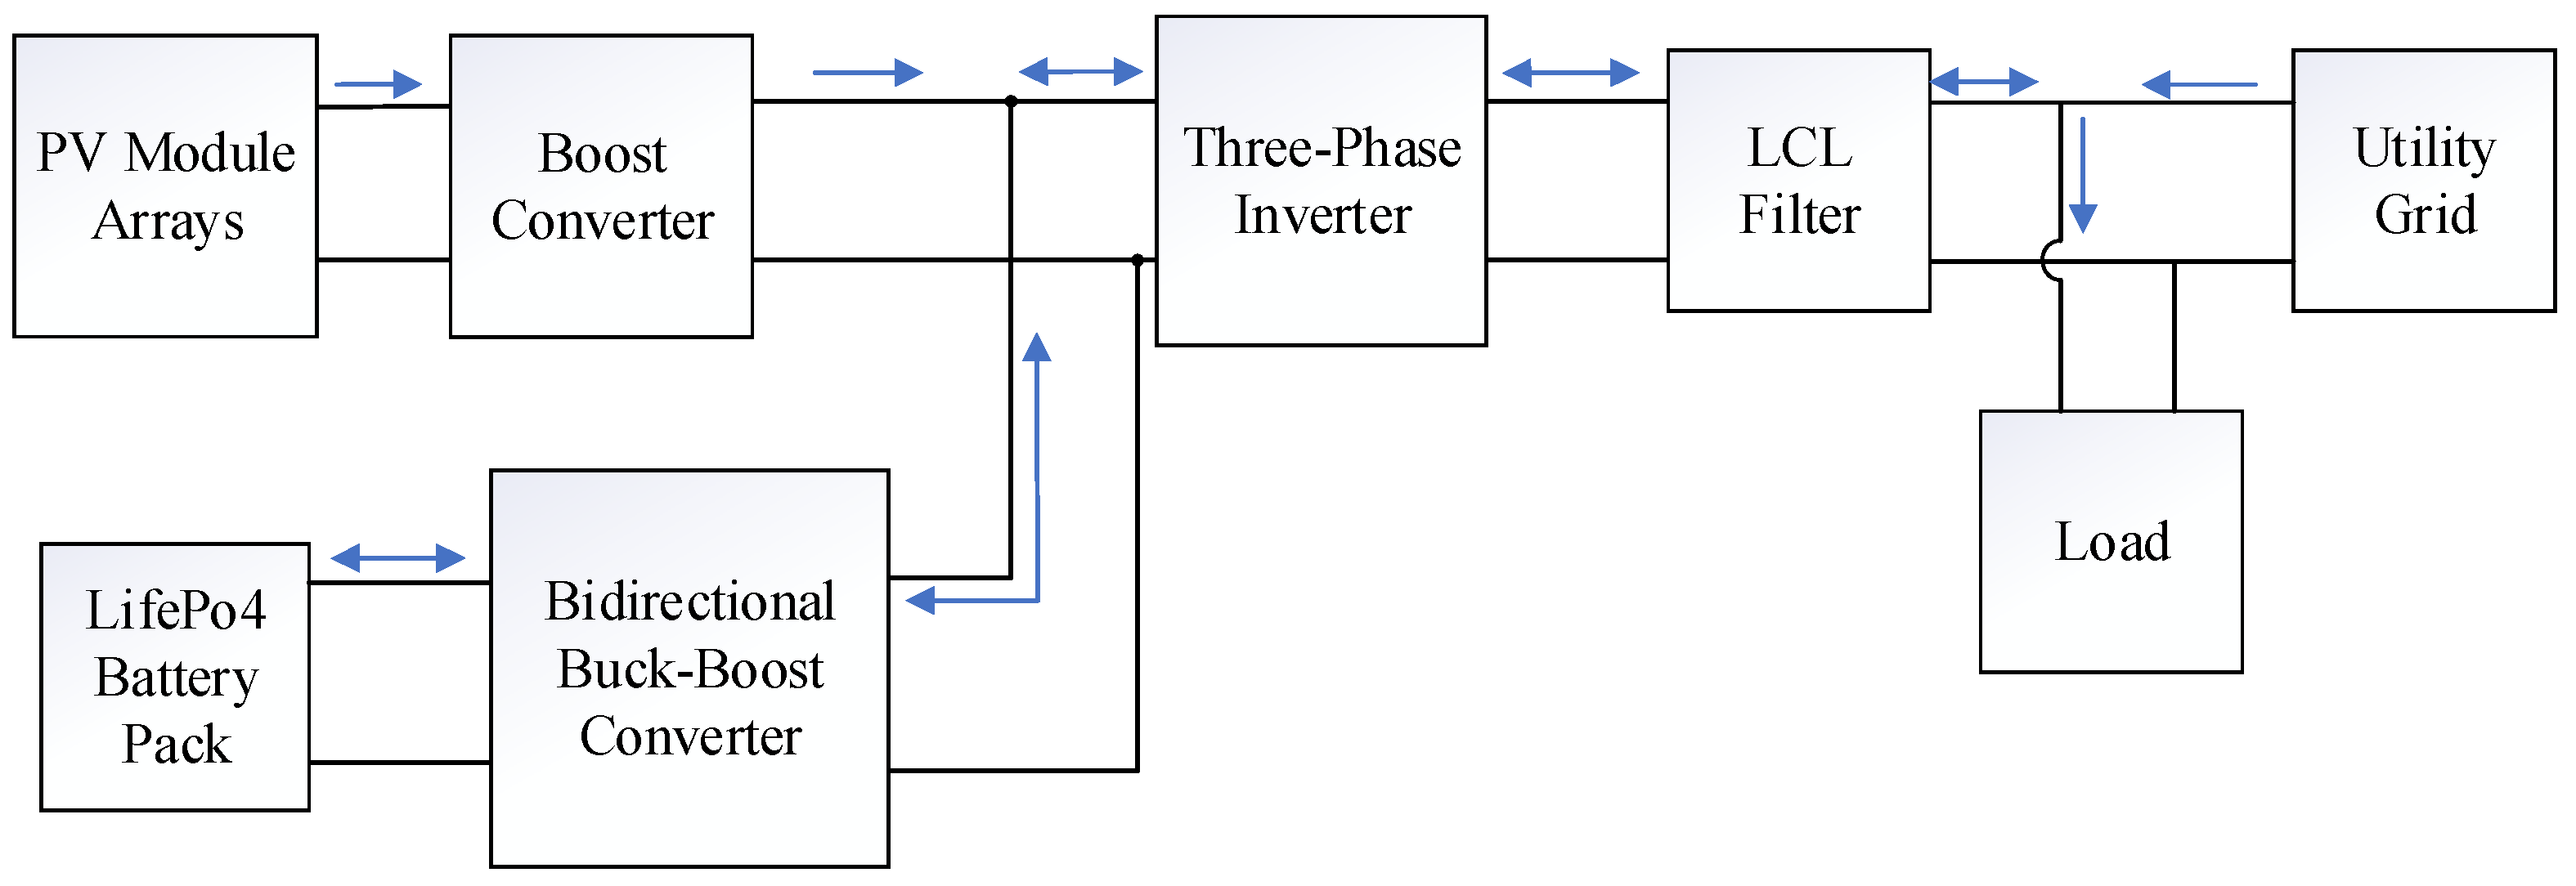
To further clarify the energy-flow logic under different operating conditions, Figure 2 and Figure 3 illustrate the power dispatch pathways of the proposed system during peak and off-peak periods, respectively. These diagrams complement the hardware architecture in Figure 1 by explicitly showing the energy exchange among the PV module arrays, battery pack, converters, and the utility grid.
Figure 2.
Energy flow during peak periods.
Figure 3.
Energy flow during off-peak periods.
2.2. Integrated Controller Design for the Proposed Grid-Connected PV-Battery System
For the DC-coupled grid-connected architecture, the controller design and system integration are implemented based on peak and off-peak periods. This includes the inverter’s DC-link voltage controller, load-following controller, peak shaving and valley-filling controller, and hysteresis current control. Additionally, it incorporates the constant current–constant voltage (CC-CV) charging controller and the anti-over-contract-capacity charging controller for the lithium-iron phosphate battery pack, as well as the maximum power point controller for the PVMAs utilizing a boost converter combined with the P and O method. The proportional and integral gains for these P-I controllers are empirically tuned based on the MATLAB/Simulink simulation environment to ensure steady-state response during peak/off-peak mode transitions and load variations.
2.2.1. Maximum Power Point Control for Photovoltaic Module Arrays
To ensure the power-generation efficiency of the PVMAs, this study adopts the P&O method [13,14] to achieve MPPT. The system dynamically adjusts the perturbation amount by observing power variations to balance the tracking response speed and steady-state oscillation losses. This ensures that the PVMAs can output maximum power continuously and stably under various solar irradiance conditions.
2.2.2. Phase-Locked Loop
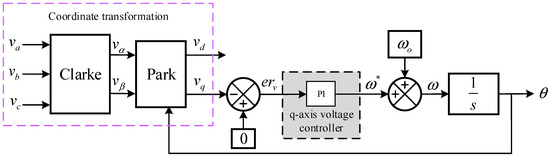
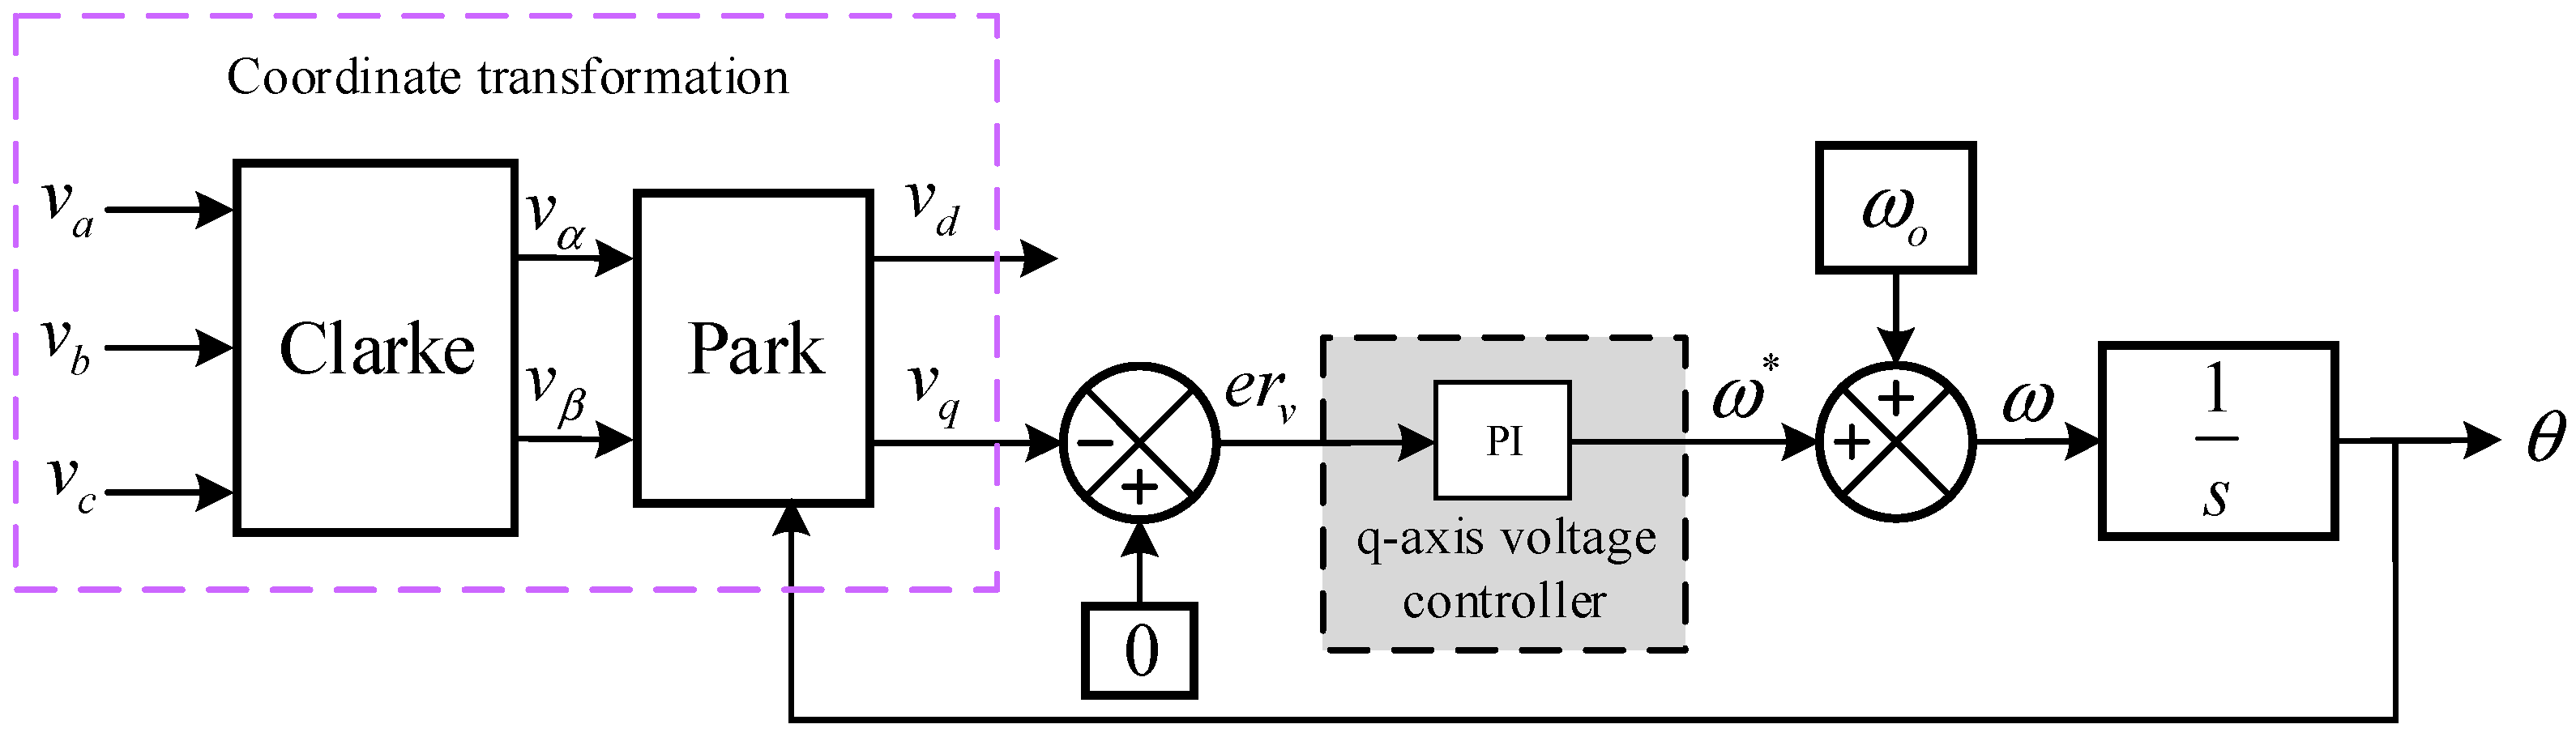
To achieve precise synchronization between the inverter and the utility grid, this study utilizes a synchronous reference frame phase-locked loop (SRF-PLL) [15] to extract the real-time phase of the grid [16]. The control architecture is illustrated in Figure 4. Through coordinate transformation [17,18], the system employs a proportional-integral (P-I) controller to force the quadrature-axis (q-axis) voltage component to zero [19], thereby locking the d-axis vector to the grid voltage phase. The calculated synchronous phase angle is continuously fed back to provide an accurate reference basis for the inverter’s grid-connected control and coordinate transformations.
Figure 4.
Architecture diagram of the SRF-PLL.
2.2.3. Energy Storage and Inverter Control During Off-Peak Periods
In this paper, a battery pack and PVMAs are connected to the DC link. The battery pack is controlled to draw power from the utility grid during off-peak periods to perform valley filling. However, since the battery pack operates with DC power for charging and discharging, the AC power from the utility must be converted into DC power via the smart inverter. The rectified output DC-link voltage is controlled to remain stable at a predefined setpoint. Subsequently, a bidirectional buck-boost converter is used to regulate the terminal voltage for battery charging. The circuit control architecture is illustrated in Figure 5.
Figure 5.
Energy storage and inverter control architecture during off-peak periods.
Constant Current–Constant Voltage (CC-CV) Charging Controller with Anti-over-Contract-Capacity Protection
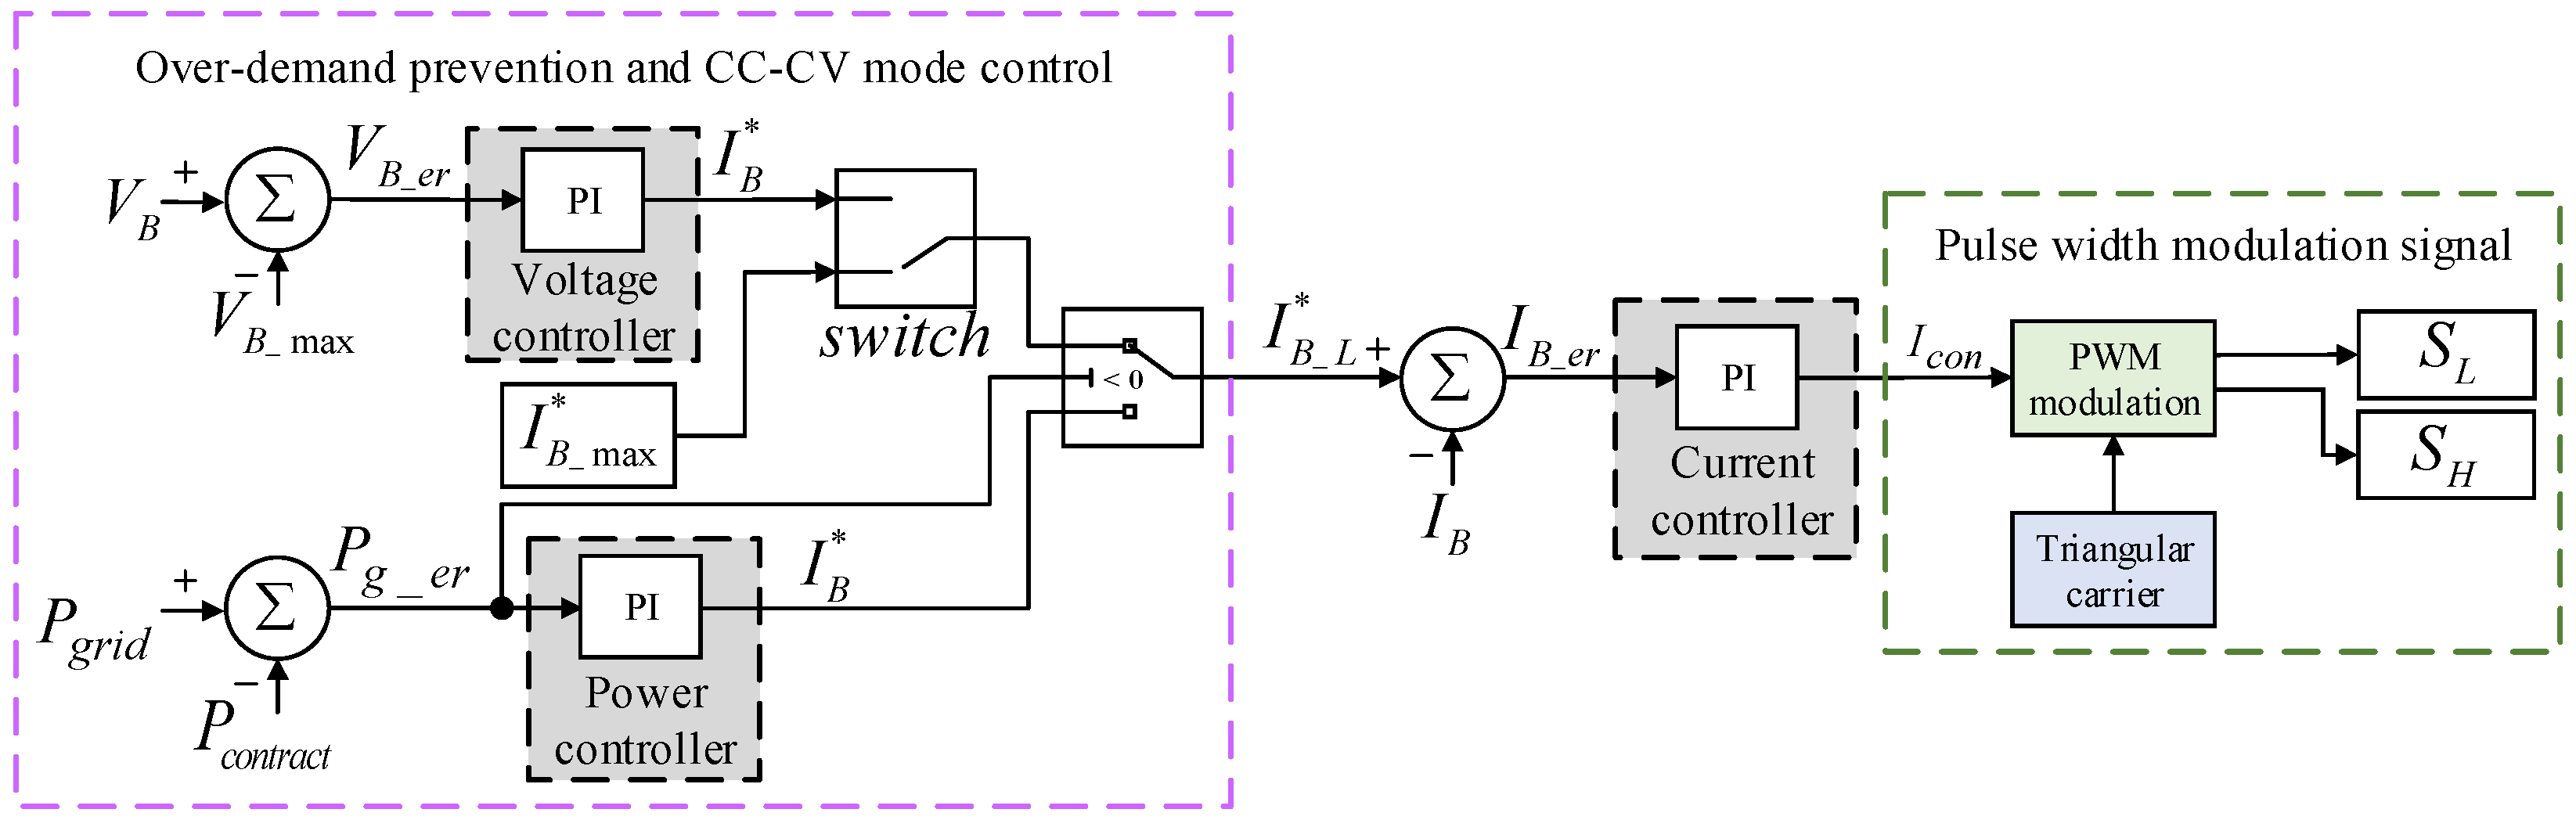
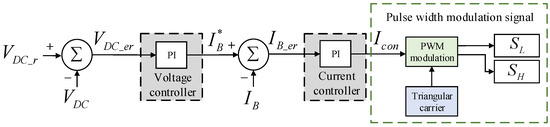
To balance the charging efficiency of the lithium-iron phosphate battery pack with the electricity costs on the utility side, this study proposes a constant CC-CV charging controller featuring anti-over-contract-capacity protection [20]. This controller is implemented using P-I controllers, and its block diagram is shown in Figure 6. During the initial stage of battery charging, to achieve constant current control, the error between the feedback battery current and the maximum charging current reference is input into a P-I controller for calculation. The governing equation is expressed as Equation (1).
where is the current control command, and are the P-I gains of the current loop controller, is the maximum charging current reference, and is the battery current.
Figure 6.
Block diagram of the CC-CV integrated charging control with anti-over-contract-capacity protection.
When the battery terminal voltage reaches its maximum allowable value, the control architecture switches to a voltage outer-loop P-I control. The error between the feedback battery voltage and the full-charge voltage setpoint is processed by the P-I controller to calculate the charging current command, as expressed in Equation (2).
where is the battery current command, and are the P-I gains of the voltage loop controller, is the battery voltage, and is the maximum battery voltage. Finally, the resulting control signal is compared with a triangular carrier wave to generate PWM signals, which control the power switches of the bidirectional buck-boost converter, thereby realizing stable and efficient CC-CV fast charging.
Considering the stochastic fluctuations of the AC-side load, if the battery is charged at a constant high current, the total demand—comprising both the charging demand and the local load—may exceed the contract capacity, risking over-contract penalties. Therefore, the power outer-loop of this controller takes the error between the measured power and the contract capacity setpoint and processes it via P-I calculation. This result is used to dynamically adjust (down-regulate) the charging reference command of the current inner-loop, as expressed in Equation (3).
where is the contract capacity power, is the actual grid power, and and are the P-I gains of the power loop.
Hysteresis Current Controller
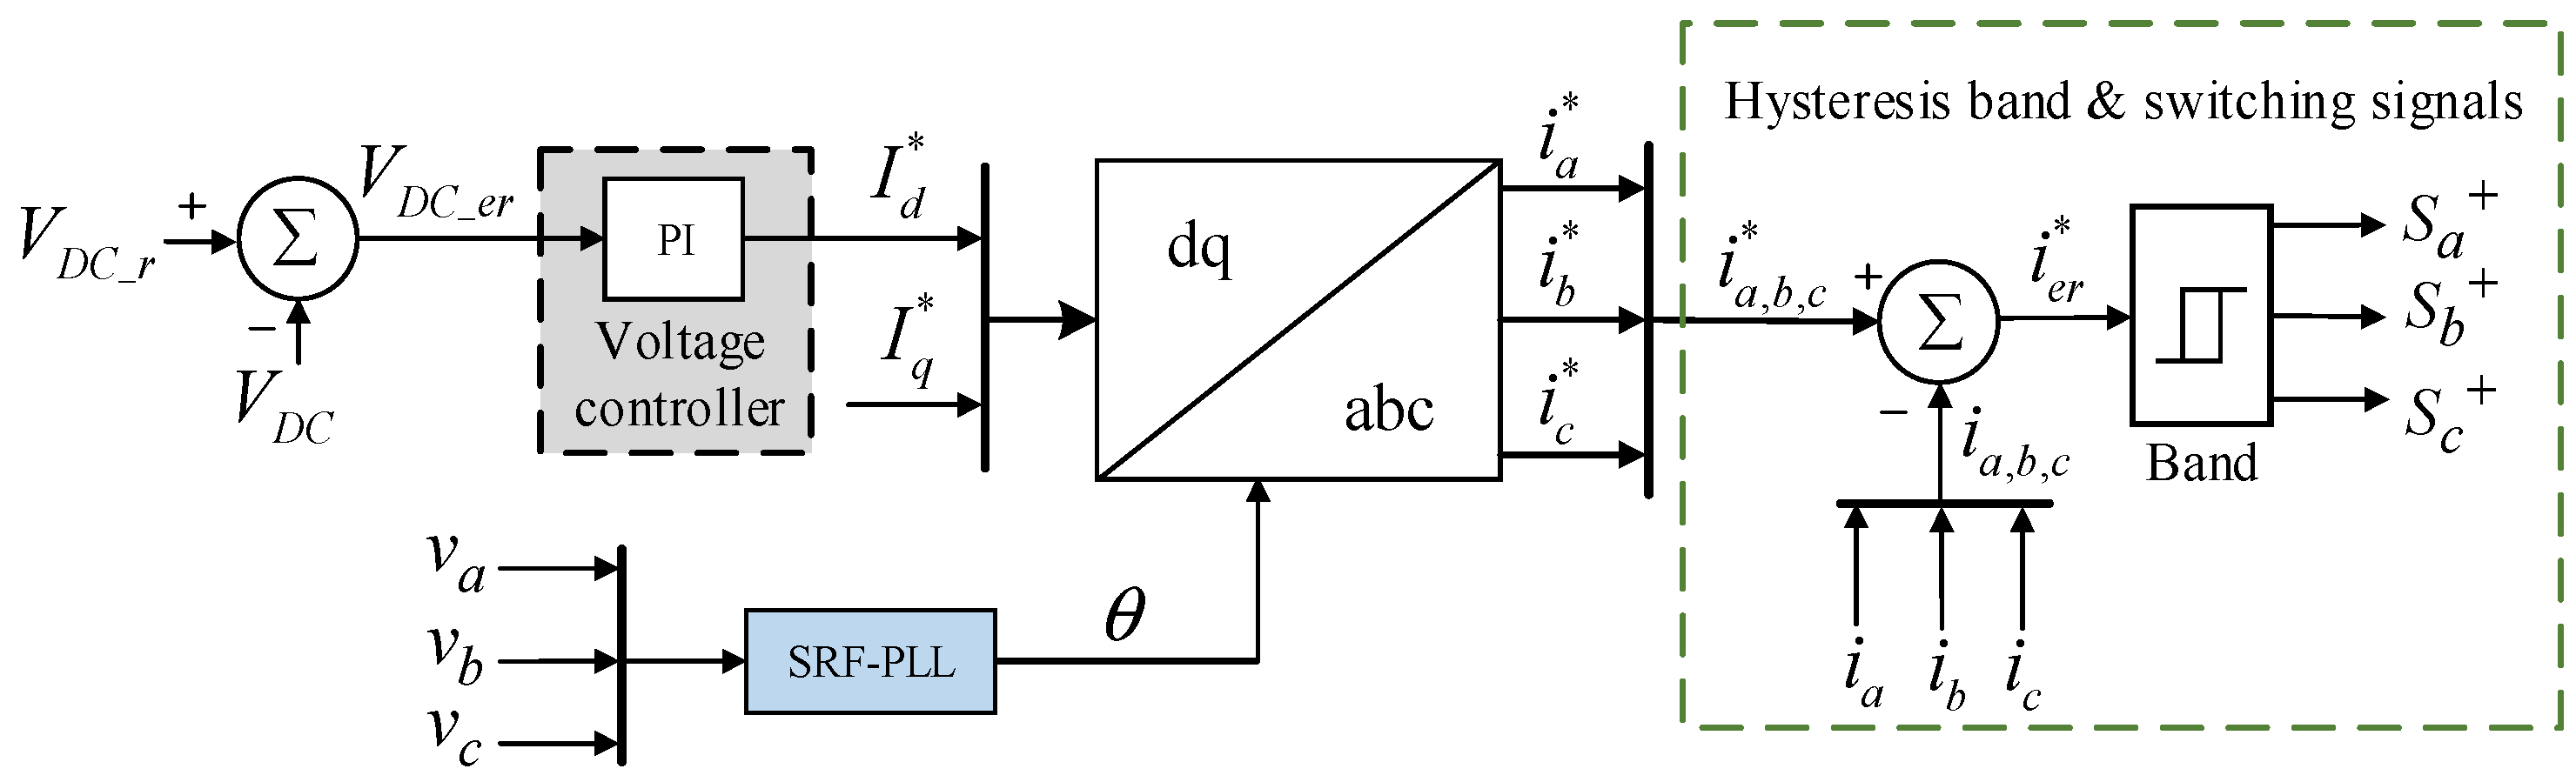
In this study, hysteresis current control [21] is employed for current regulation and its control block diagram is illustrated in Figure 7. First, the system captures the actual DC-link voltage and compares it with the reference voltage. The resulting error is processed by a P-I controller to obtain the required reference component for the AC-side d-axis current, as expressed in Equation (4).
where is the d-axis reference current, is the dc-link reference voltage, is the dc-link voltage, and and are the P-I gains of the dc-link voltage controller.
Figure 7.
Block diagram of the hysteresis current control.
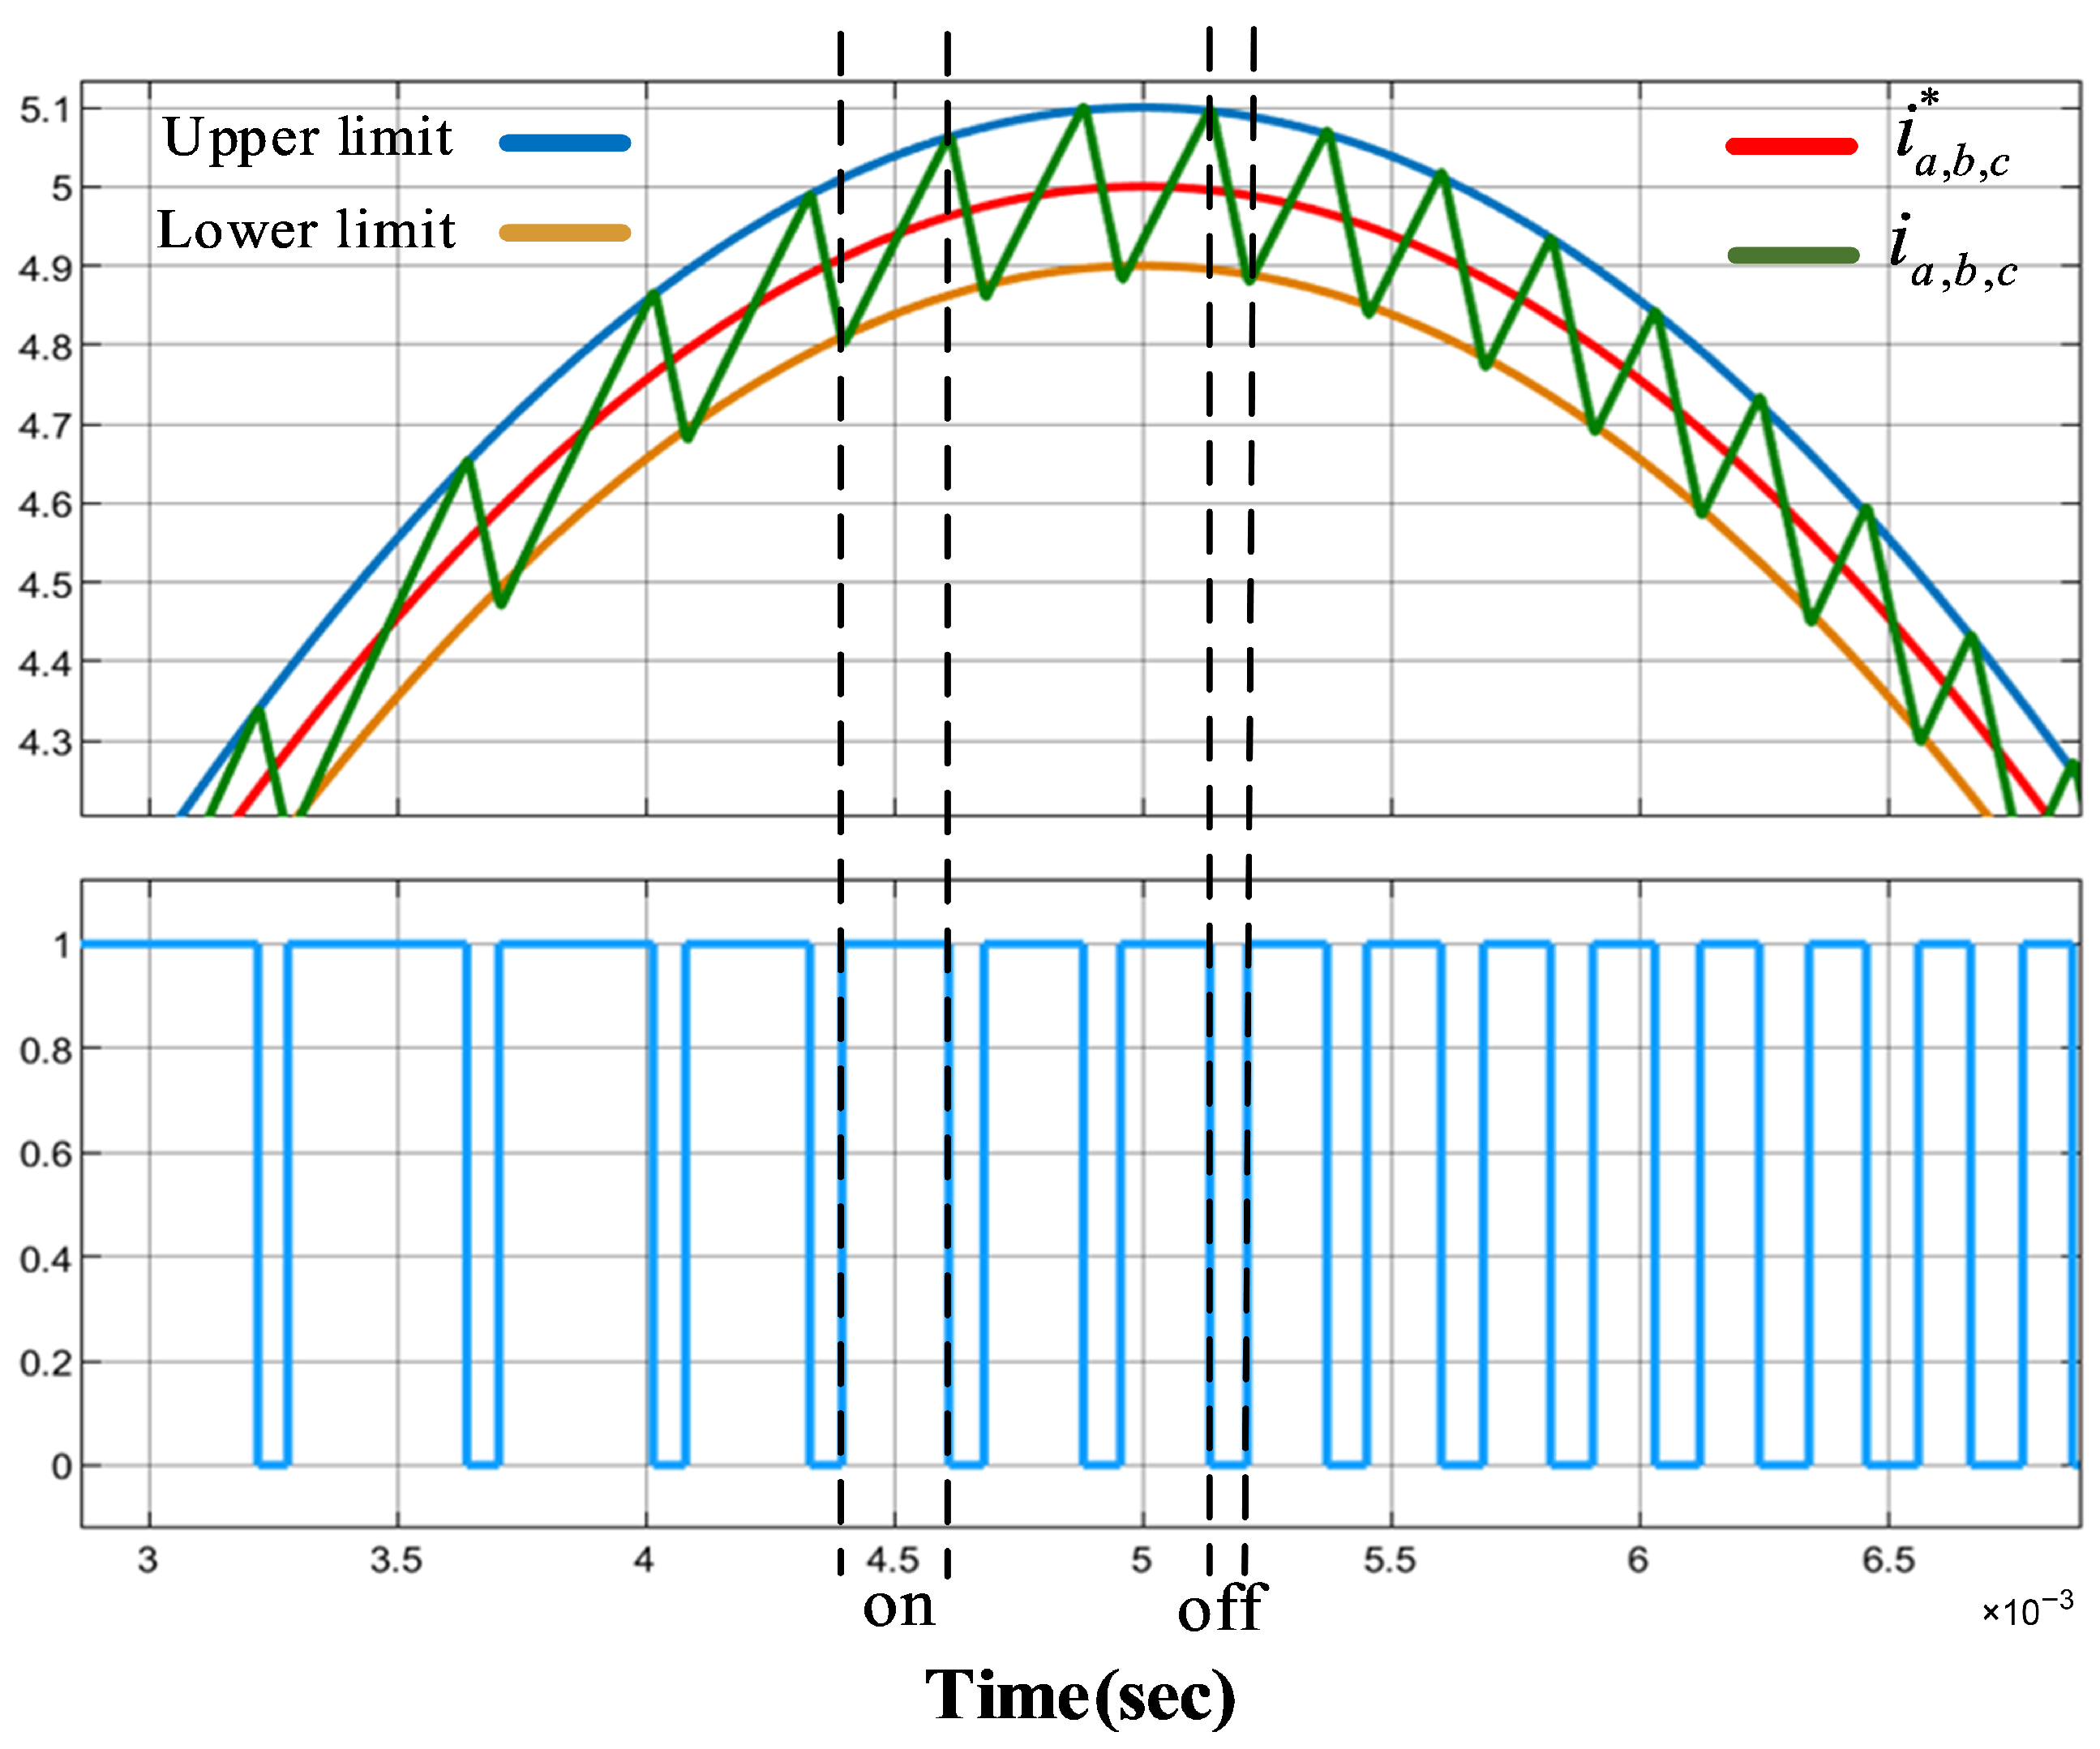
Subsequently, the system utilizes the phase angle provided by the phase-locked loop (PLL) to transform the d-axis and q-axis current components into three-phase AC reference currents. Following this, the measured grid currents are compared with these reference currents, and their errors are restricted within a predefined hysteresis band. This process directly triggers the switching of the inverter’s bridge arms. A comparison between the current and switching signals is illustrated in Figure 8. This control method features a rapid dynamic response and forces the actual current to accurately track the current command, thereby achieving PFC and effectively improving the THD.
Figure 8.
Comparison of current and switching control signals in hysteresis current control.
2.2.4. Energy Storage and Inverter Control During Peak Periods
After the off-peak period ends, the control strategy shifts to supplying power to the AC-side load using the PVMAs and the lithium-iron phosphate battery pack connected in parallel to the DC link, as electricity prices are higher during peak periods. To compensate for electricity consumption exceeding the contract capacity, the proposed DC-coupled power system must be controlled to perform energy dispatching for both the PVMAs and the battery pack. Accordingly, this section discusses the integration and design of controllers under various conditions based on the battery’s SOC and whether the contract capacity is exceeded, ensuring the stable operation of the power system. The control architecture is illustrated in Figure 9.
Figure 9.
Energy storage and inverter control architecture during peak periods.
Inverter Active Power Dispatch and Peak Shaving Controller Design
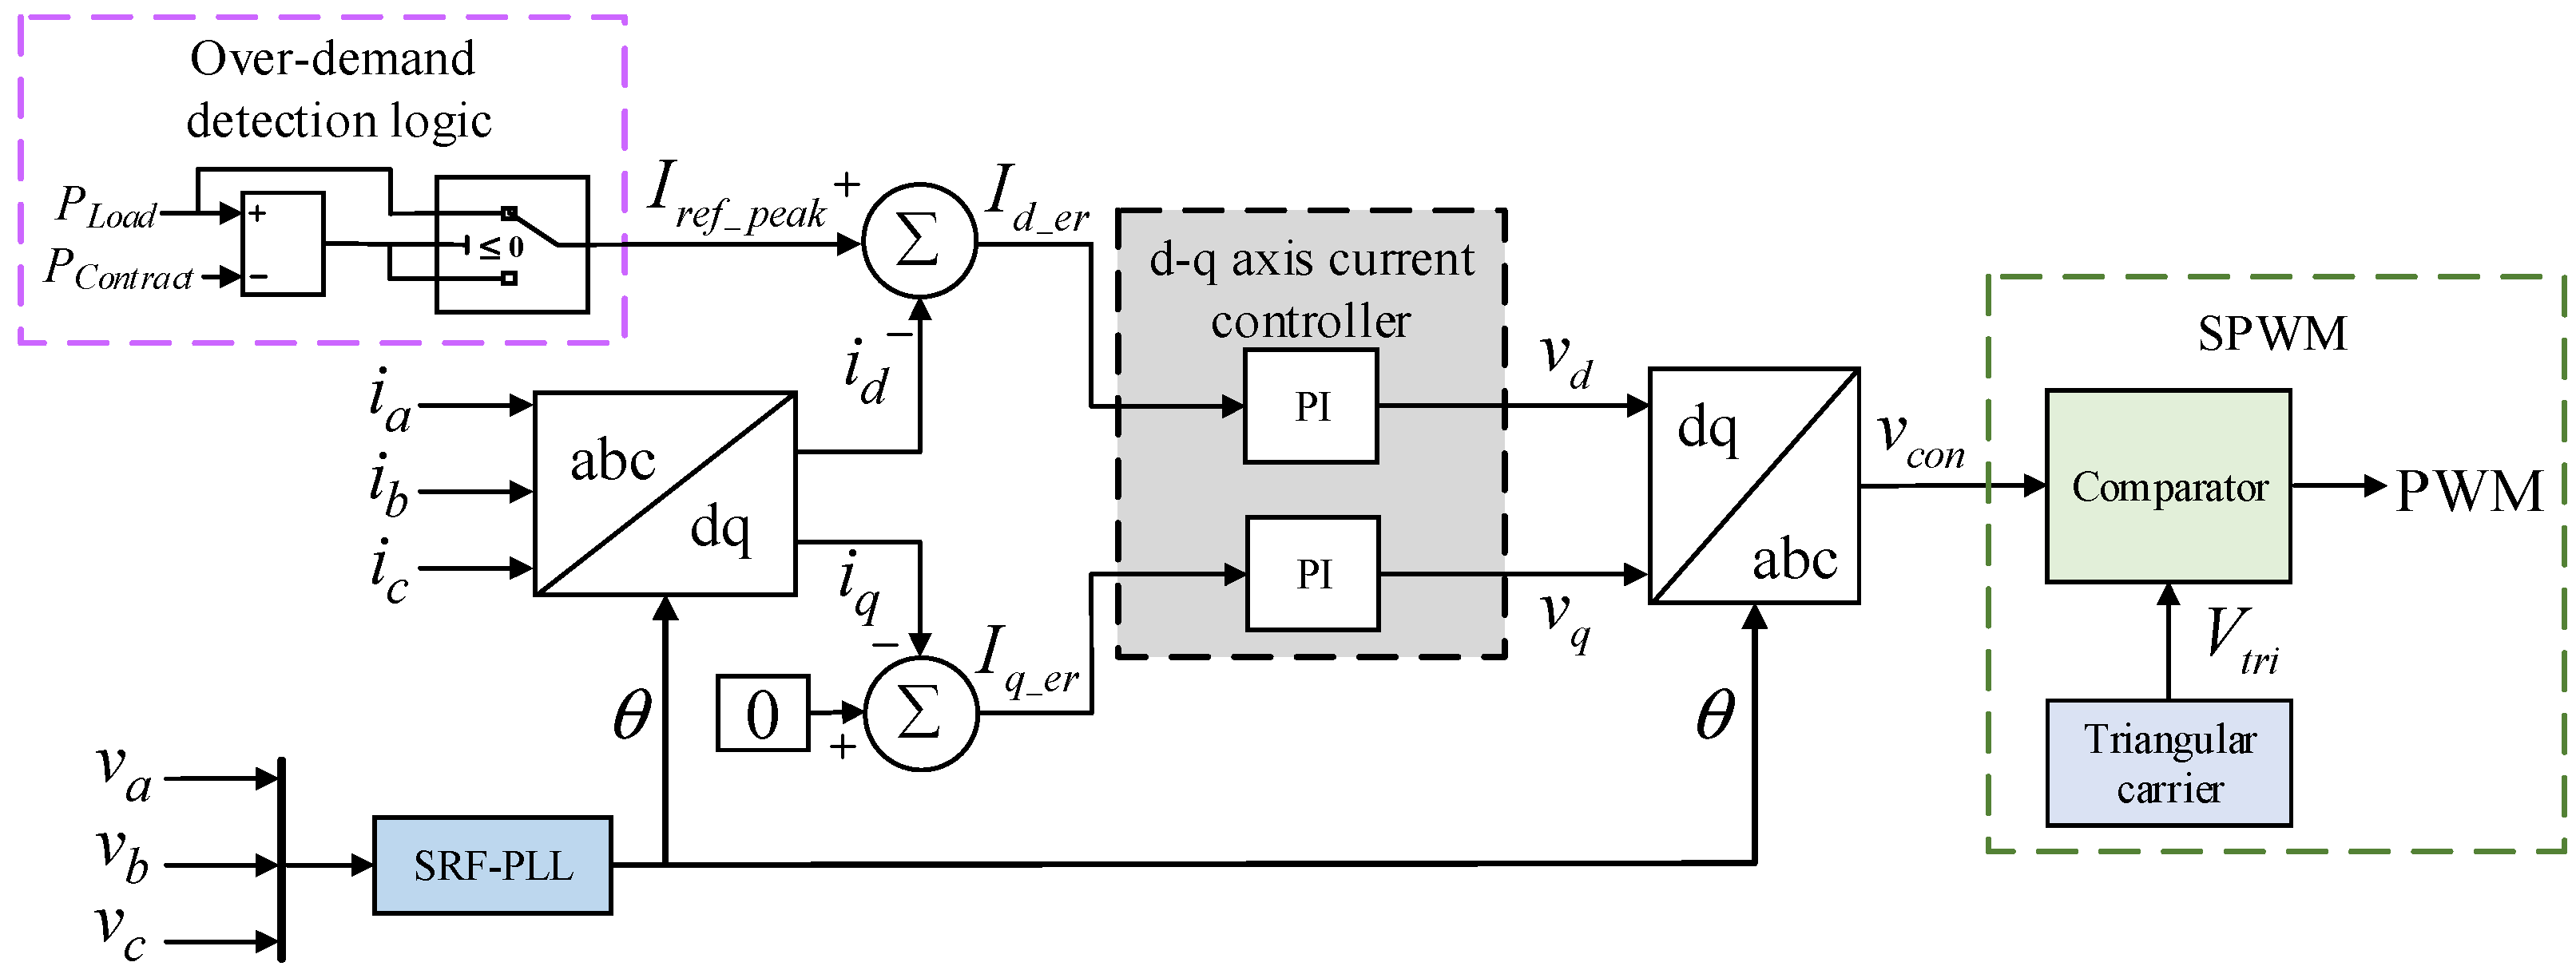
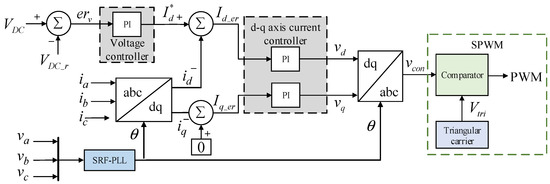
During peak electricity demand periods, the system control strategy actively regulates the inverter’s output active power to supply the AC-side load. To balance the discharge depth of the lithium-iron phosphate battery and prevent the utility contract capacity from being exceeded, this study integrates “load following” and “peak shaving control” into a single active power dispatch architecture. The control block diagram is illustrated in Figure 10. The control strategy first compares the actual load demand with the contract capacity to dynamically determine the calculation path for the d-axis current reference value. If the load demand is less than the contract capacity, the system enters the load-following control mode, where the inverter is controlled to ensure that the power supply is equal to the load demand. To control the inverter’s output power according to the load requirements, the system performs power measurement on the AC-side load to provide feedback signals [22]. The load current required is then obtained through Equations (5) and (6) to serve as the d-axis current reference for the current control loop.
where is the reference power, is the reference peak current, and is the peak grid voltage.
Figure 10.
Block diagram of the inverter active power dispatch and peak shaving controller.
Conversely, when the load is excessive, leading to a situation where the load demand exceeds the contract capacity, relying solely on the lithium-iron phosphate battery pack to fully compensate for the required load power would result in an excessively high discharge current and a rapid decline in the SOC. Once the battery is depleted, it may be unable to perform compensation during other periods of over-contract power consumption. To effectively dispatch the energy of the storage system, the system automatically switches to the peak shaving control mode. In this mode, the instantaneous power error between the load demand and the contract capacity is first calculated by Equation (7), and the current required for peak shaving is subsequently obtained via Equation (8) to serve as the inverter’s output current reference.
where is the peak shaving power and is the load demand power.
After determining the d-axis current reference based on the aforementioned conditions, the q-axis current reference is set to zero to maximize the power generation utilization rate of the PVMAs, ensuring that the inverter output consists entirely of active power. After comparing the errors of the d-axis and q-axis current components, the respective voltage components are obtained through P-I controllers, as expressed in Equations (9) and (10).
where and are the voltage component of the d-axis and q-axis, respectively, and are the P-I gains of the d-axis current controller, and and are the current of the d-axis and q-axis, respectively.
Finally, these two-axis voltage components undergo inverse coordinate transformation (from axis to axes) and are combined with sinusoidal pulse-width modulation (SPWM) technology to generate PWM signals to drive the switching elements within the inverter.
Design of the Lithium-Iron Phosphate Battery Charge/Discharge Controller
The inverter controller described in Section “Inverter Active Power Dispatch and Peak Shaving Controller Design” is responsible for regulating the magnitude of the load current output to the AC side. To ensure that the inverter operates stably within the linear modulation region, the control block diagram is illustrated in Figure 11. The DC-link voltage error is obtained by comparing the actual feedback DC-link voltage with its reference value. This error is then processed through a P-I controller to output the battery charge/discharge current command, as expressed in Equation (11). Once the charge/discharge current command has been obtained, it is subtracted from the actual feedback battery current to determine the error. Subsequently, an inner-loop P-I controller is used to generate the control signal, as shown in Equation (12). Finally, the PWM signals for driving the bidirectional buck-boost converter are generated through PWM control.
where and are the P-I gains of voltage outer loop controller and and are the P-I gains of the current inner loop controller.
Figure 11.
Block diagram of the lithium-iron phosphate battery charge/discharge control.
Design of the Inverter DC-Link Voltage Controller
When the lithium-iron phosphate battery pack is no longer capable of regulating the DC-link voltage, the inverter must be used to stabilize the DC-link voltage at a predefined setpoint to supply the energy generated by the PVMAs to the grid side. Specifically, when the PV power generation exceeds the demand, the excess power is controlled to flow into the grid. Conversely, when the PV power generation is lower than the load demand, the grid compensates for the deficit. The control block diagram employed for this purpose is illustrated in Figure 12 [23].
Figure 12.
Block diagram of the inverter DC-link voltage control.
As the PVMAs continue to supply power with increasing solar irradiance, the actual DC-link voltage will rise. At this point, the current error command of the inner-loop current controller must be positive to control the inverter to output a larger current, thereby reducing the DC-link voltage. Therefore, in the voltage outer-loop control circuit, the actual measured DC-link voltage must be controlled using positive feedback. This ensures that the voltage error compared with the reference value remains positive. After processing this error through a P-I controller, the output current command required by the inverter to stabilize the DC-link voltage is obtained as a positive and increasing value, as expressed in Equation (13). This control framework is similar to the inverter control described in Section “Inverter Active Power Dispatch and Peak Shaving Controller Design”, with the only difference being the inclusion of the voltage outer-loop control circuit; thus, further details are omitted.
where and are the P-I gains of the dc-link voltage controller.
3. Simulation Results
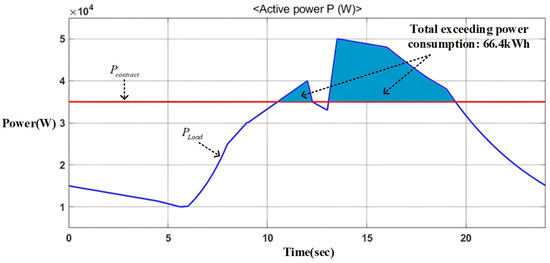
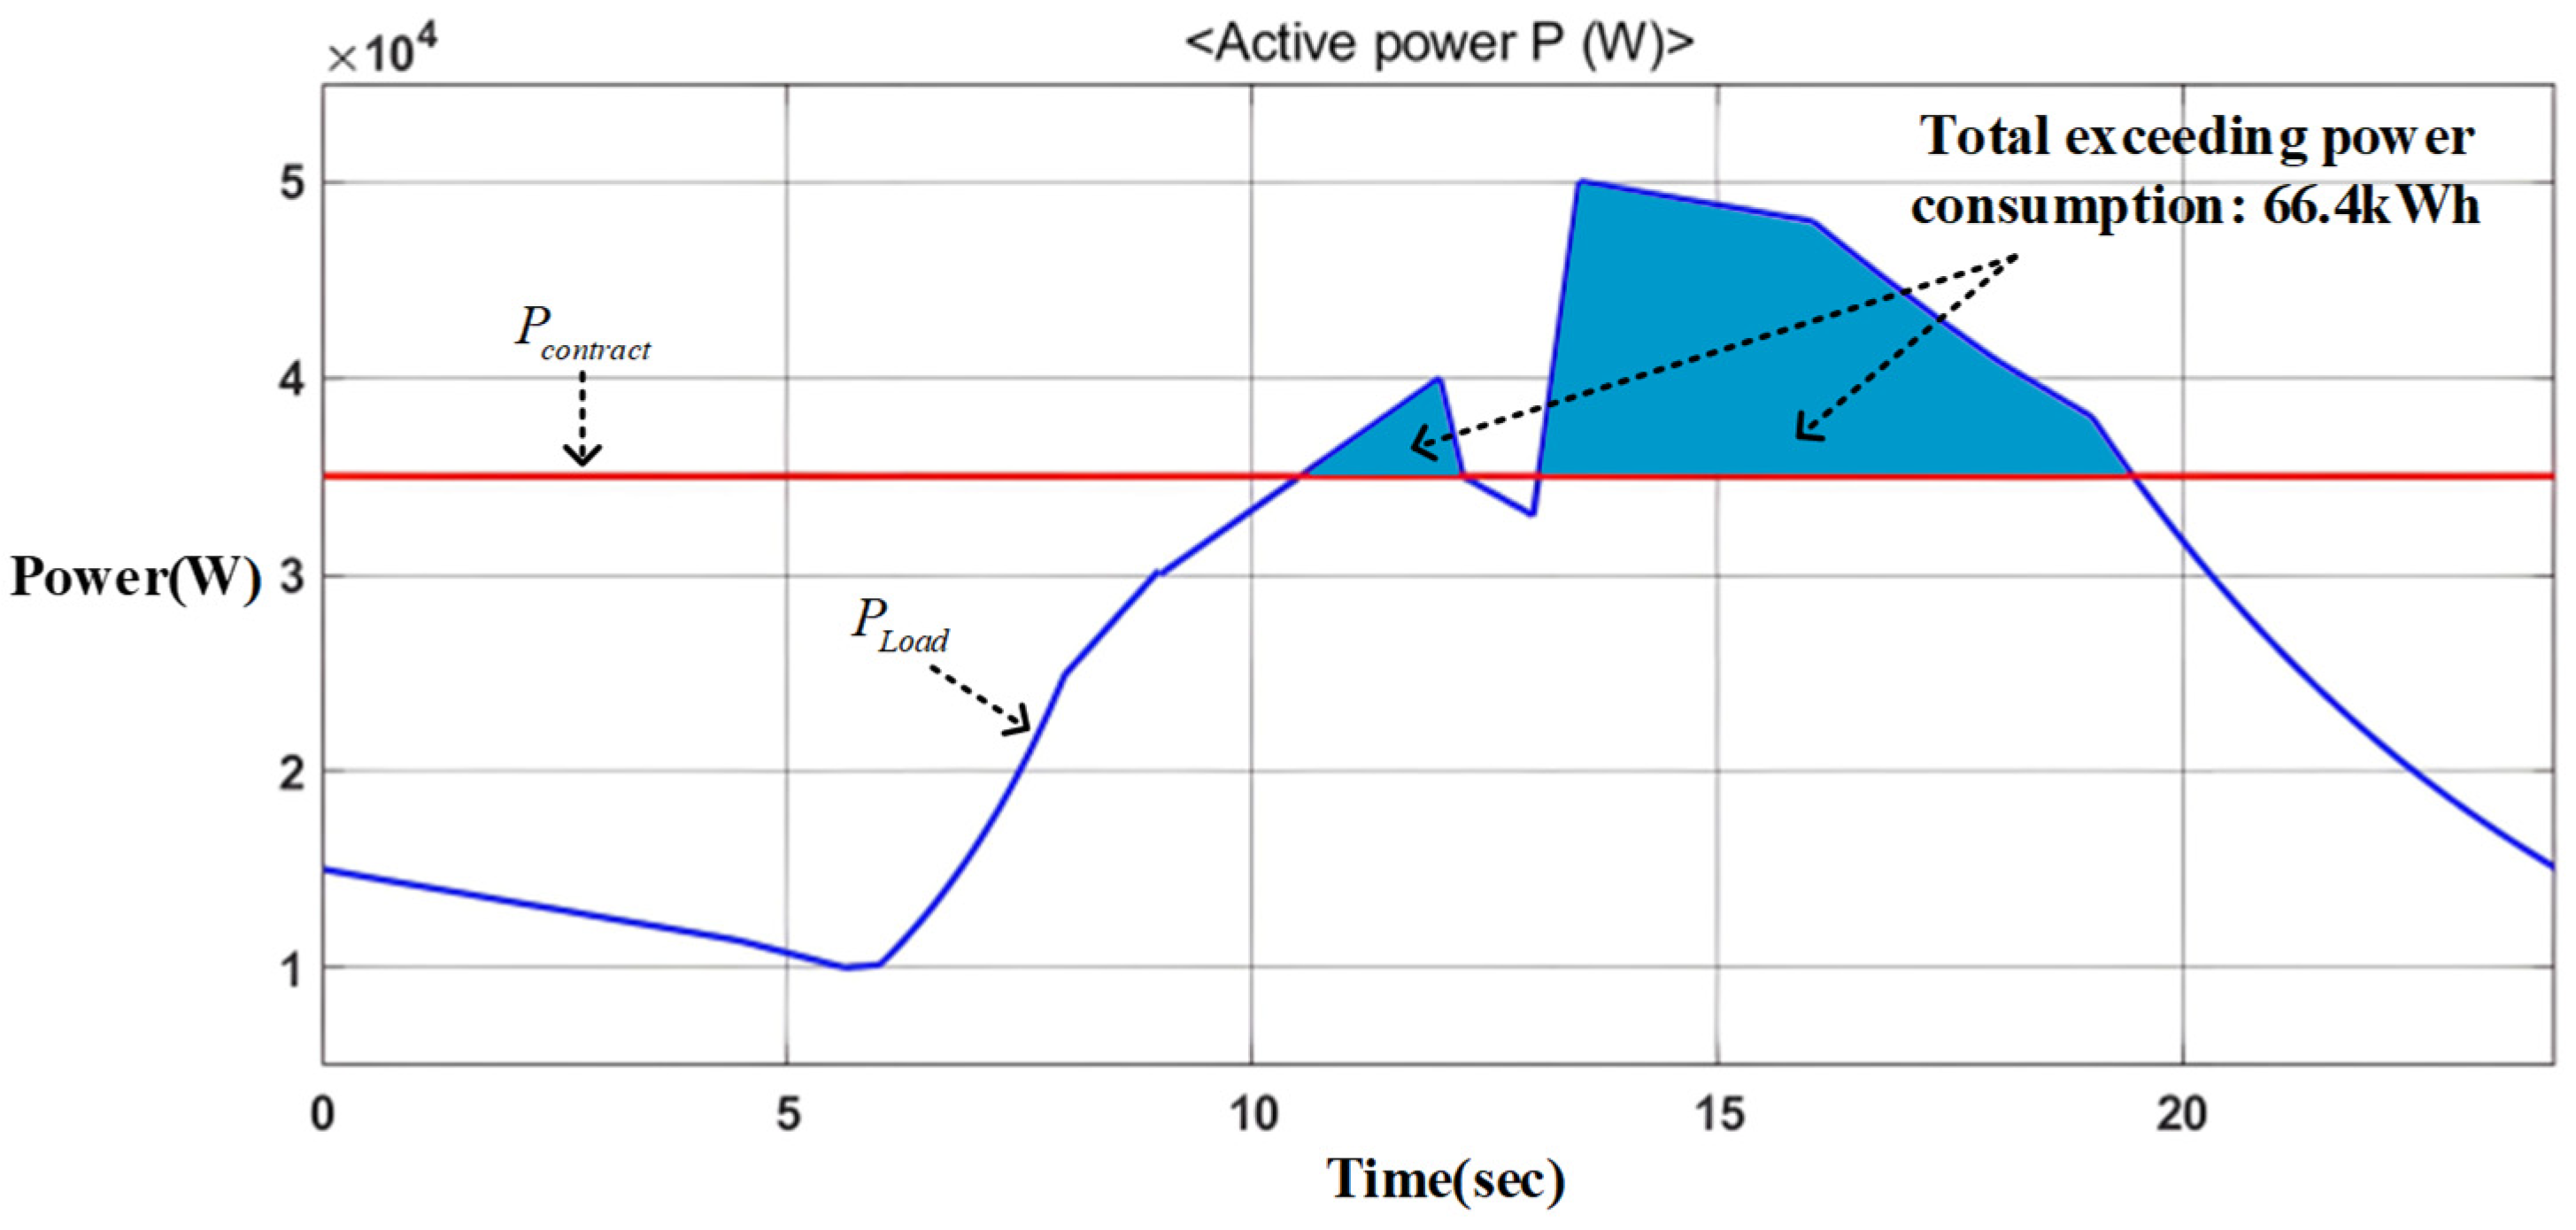
Based on the daily load profile and the contract capacity schematic shown in Figure 13, integrated control for both off-peak and peak periods was simulated using Matlab/Simulink. The performance of the proposed control strategy when applied to the main circuit architecture of the power system was also observed. The design specifications for the three-phase grid-connected inverter proposed in this study include a DC-link voltage of 800 V and an output AC voltage with an effective (RMS) value of 380 V at a frequency of 60 Hz. The lithium-iron phosphate battery pack has a rated voltage of 287.1 V and a capacity of 93.1 kWh. The total capacity of the PVMA, configured with 22 series and five parallel strings, is 24.7 kW. The electrical specifications for the PV modules [24] and the lithium-iron phosphate batteries [25] are summarized in Table 5 and Table 6, respectively.
Figure 13.
Schematic diagram of the plant’s daily load profile and contract capacity.
Table 5.
Electrical specifications of the A10 Green Technology A10J-M60-225 photovoltaic module.
Table 6.
Electrical specifications of the lithium-iron phosphate battery.
3.1. Simulation of Maximum Power Point Tracking
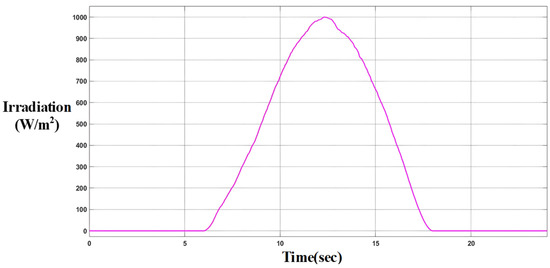
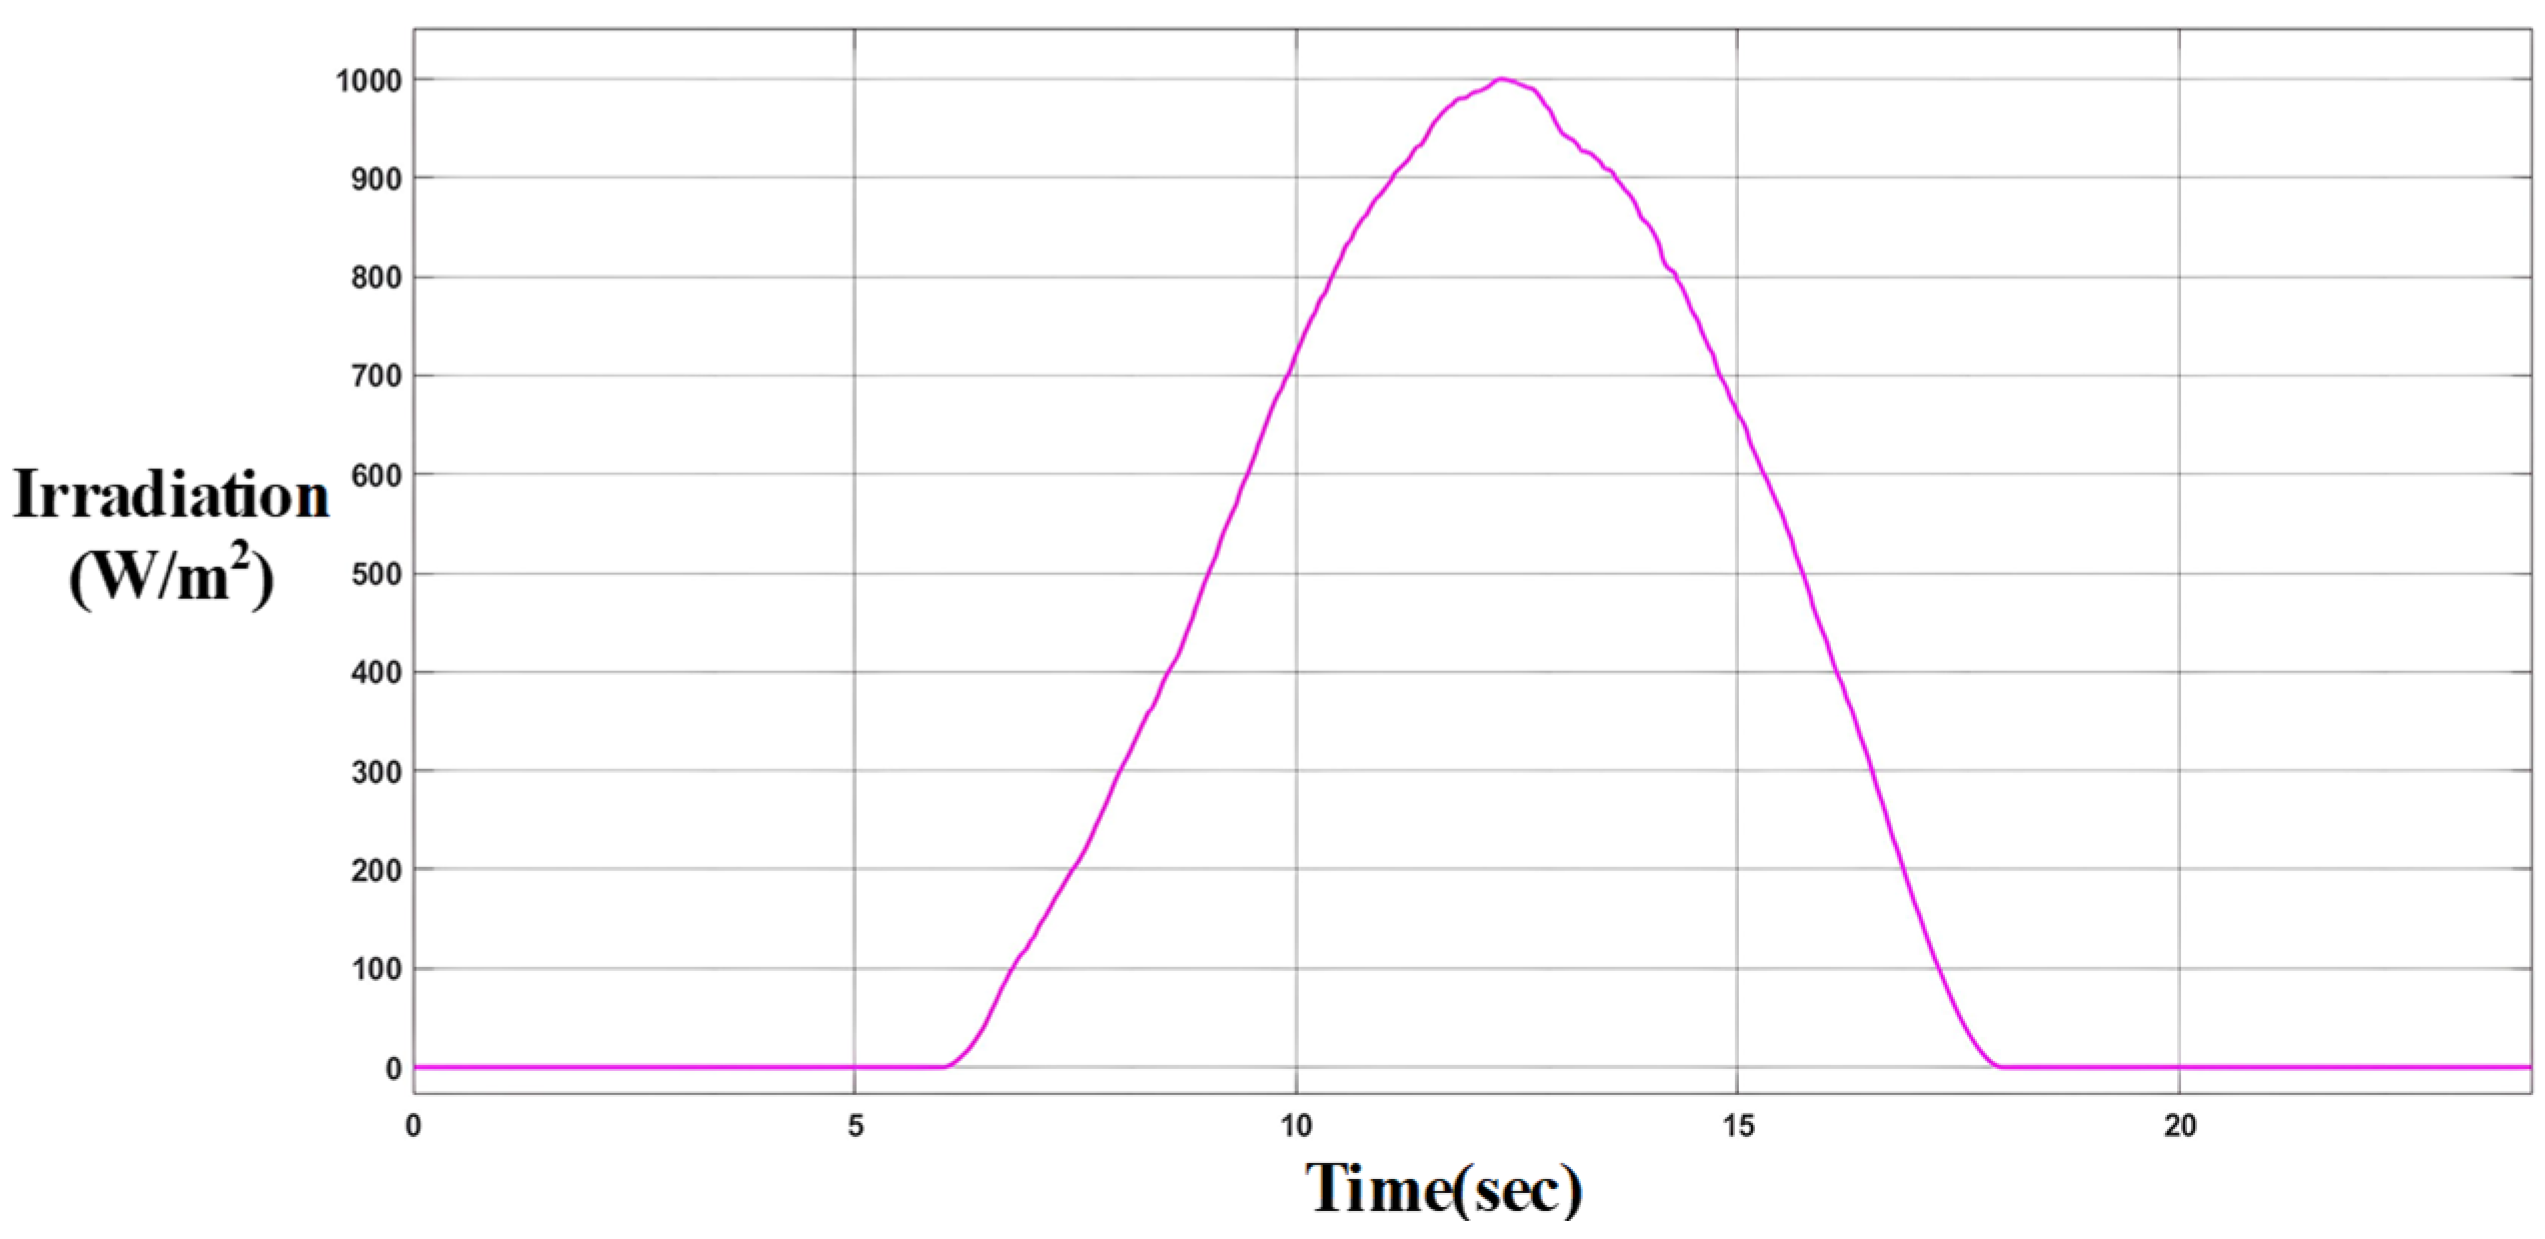
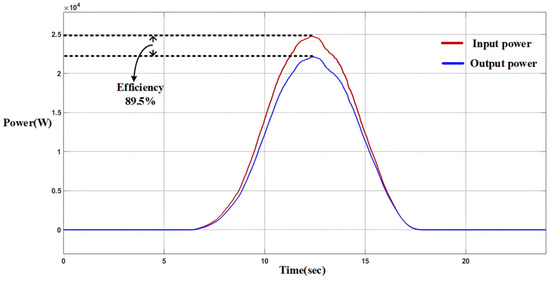
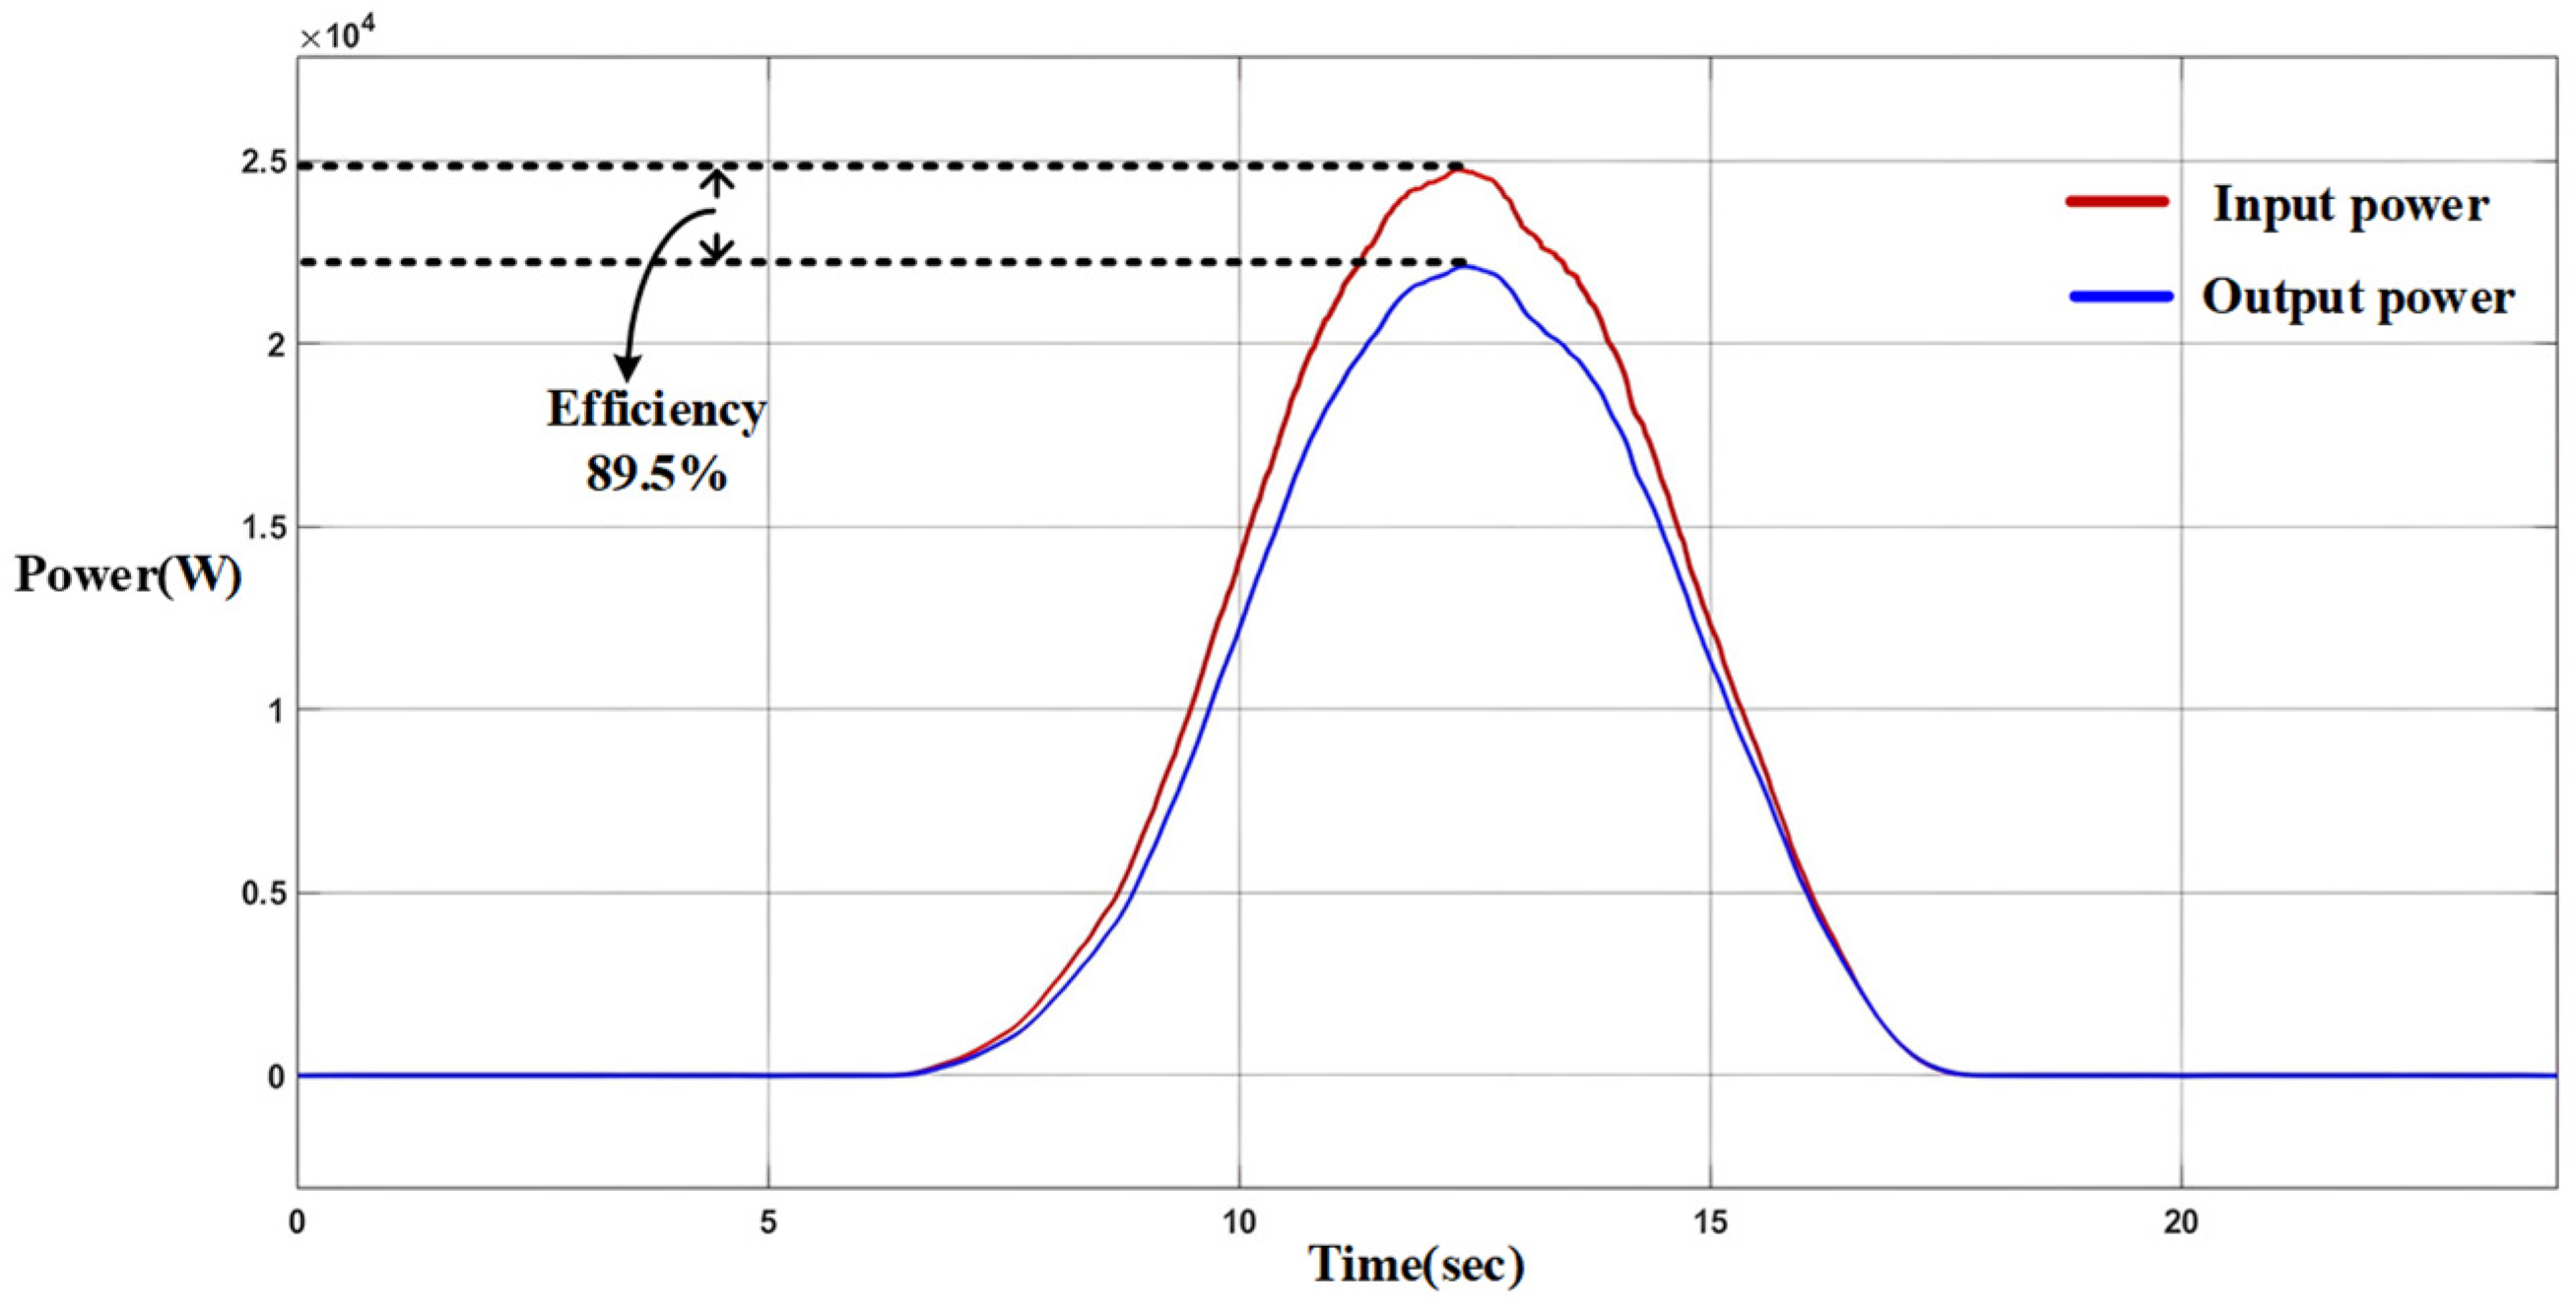
In this study, the assumed solar irradiance profile is shown in Figure 14. A boost converter employing the P&O method is used to implement MPPT control under continuously varying irradiance levels. By observing the relationship between the input power and output power of the converter in Figure 15, the power conversion efficiency of the converter under standard test conditions (STC) is determined to be 89.5%. This value reflects comprehensive losses, including inductor parasitic resistance, switching losses at a 15 kHz frequency, and the non-ideal characteristics of analog circuit components within the HIL platform.
Figure 14.
Assumed solar irradiance profile.
Figure 15.
Conversion efficiency of the boost converter.
3.2. Simulation of Peak Shaving and Valley-Filling Control Under Different Battery SOC
This section simulates the steady-state response performance of the integrated control for the DC-coupled three-phase grid-connected PV-battery system during peak and off-peak periods under various battery charge levels. The system operating states under “fully charged” and “insufficient power (low SOC)” conditions of the battery pack are simulated and discussed in Section 3.2.1 and Section 3.2.2, respectively. In this study, the battery state-of-charge (SOC) information is directly obtained from the battery model implemented in the MATLAB/Simulink environment and is used by the proposed energy management controller to determine the battery operating state. To mitigate battery stress and enhance long-term operational reliability, a conservative 0.2 C (65 A) constant-current (CC) charging strategy is adopted. In addition, the battery SOC is restricted to the range of 10–90% to prevent deep discharge and overcharge conditions. These measures help to reduce battery temperature rise and charging stress, thereby contributing to improved battery lifespan and stable system operation. Furthermore, a state-locking mechanism is implemented to prevent frequent charge/discharge transitions caused by measurement noise near the SOC protection thresholds. In addition, the inverter limits, current saturation, and DC-link voltage bounds are not taken into account, as no instances of rating exceedance were observed during actual operation.
3.2.1. Simulation of the Lithium-Iron Phosphate Battery Pack Under Sufficient SOC
Case 1: Battery SOC at 50%
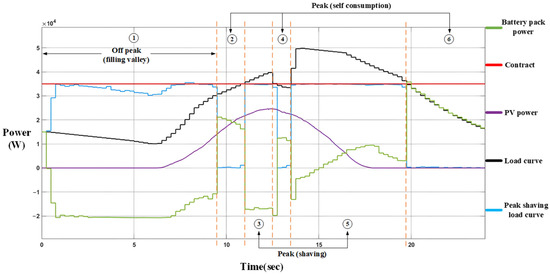
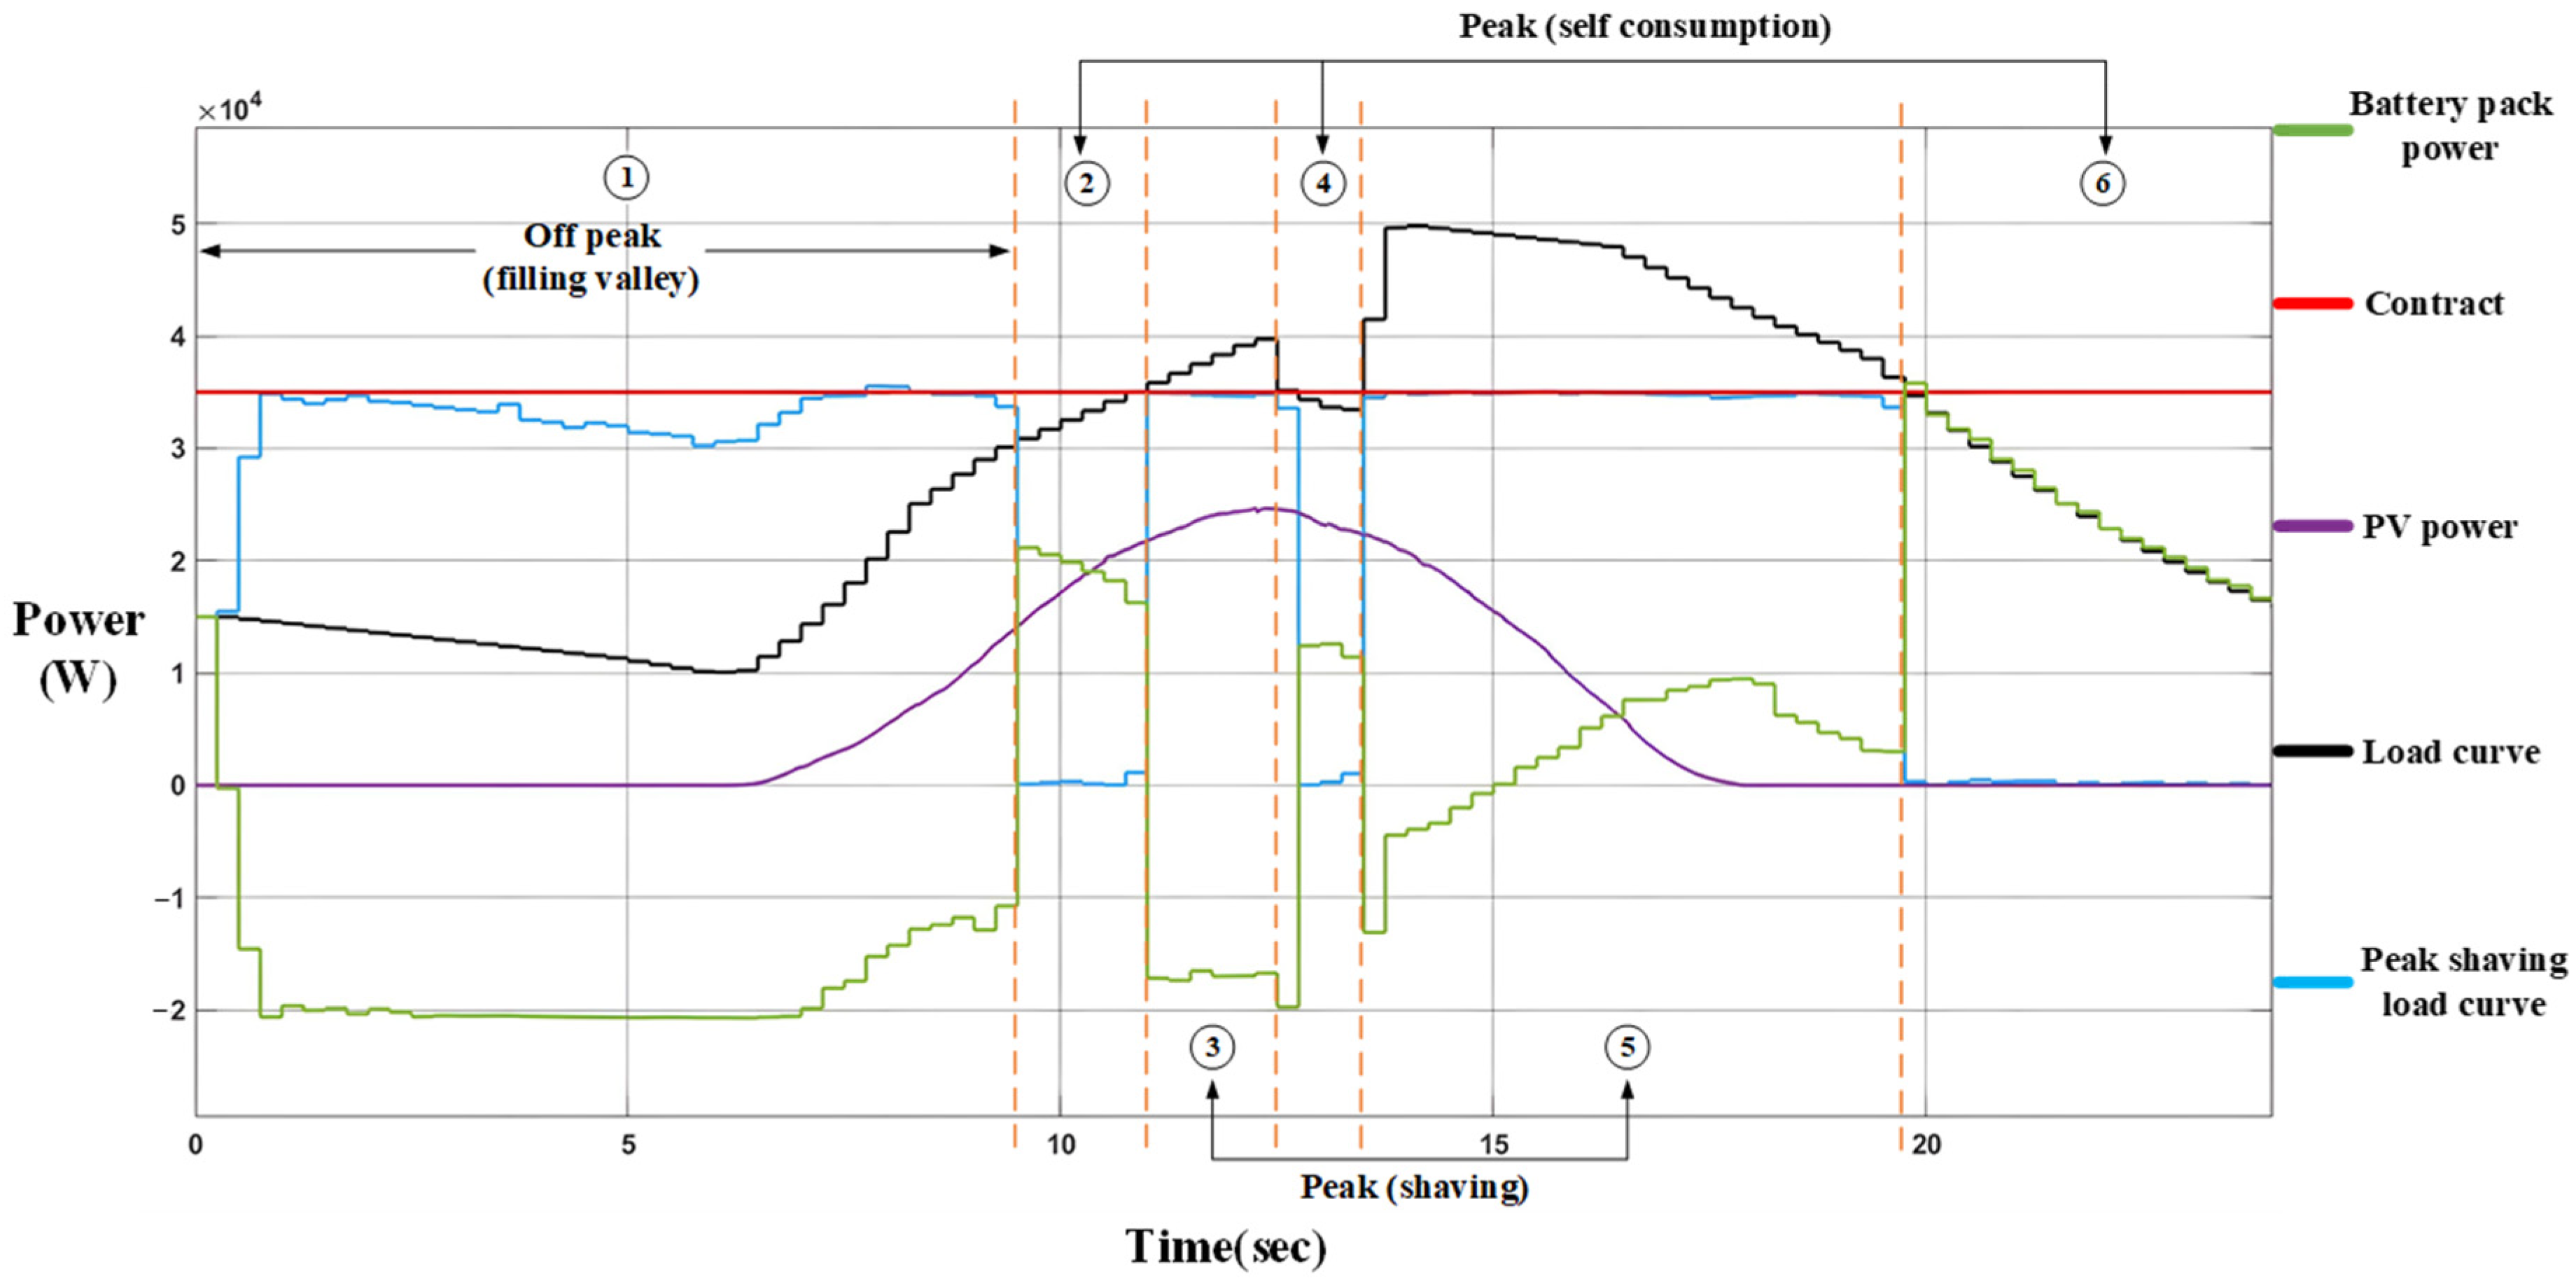
According to the daily load profile comparison of peak shaving and valley-filling control (SOC at 50%) in Figure 16, the operating states can be divided into six stages, which are described as follows.
Figure 16.
Comparison of daily load profiles with peak shaving and valley-filling control (battery SOC at 50%).
- Stage 1
- The lithium-iron phosphate battery pack is charged by the grid using constant current (power is defined as negative). As the time approaches the peak period, the PVMAs begin to generate power, alleviating the supply pressure on the grid. However, as the load demand rises rapidly, continuous constant current charging would lead to the contract capacity being exceeded. Therefore, the battery charging power must be controlled to decrease gradually as the grid supply increases to avoid over-contract penalties.
- Stage 2
- Upon entering the peak electricity demand period, the load demand has not yet exceeded the contract capacity. To minimize electricity costs, a self-consumption PV energy dispatch control is adopted, and the battery pack provides auxiliary power to the load (power is defined as positive).
- Stage 3
- The load demand exceeds the contract capacity, forming the “first peak.” At this time, the PVMAs output the current required for peak shaving through the inverter. Since the PV power generation is currently in surplus, the battery pack stores the excess energy, ensuring that the power drawn from the grid is controlled within the contract capacity limits to facilitate energy dispatching for the subsequent “second peak”.
- Stage 4
- During the plant’s lunch break, the load demand falls below the contract capacity. Power is released from both the PVMAs and the battery pack to the load, bringing the grid power supply close to zero.
- Stage 5
- The load demand enters the “second peak.” Observing the power variation in the battery pack, it initially stores the surplus PV energy. As solar irradiance declines, the battery switches to auxiliary power supply. Consequently, the post-control grid power is successfully suppressed within the contract capacity.
- Stage 6
- Upon entering the night-time period, due to the absence of solar irradiance, the battery pack—which has sufficient residual energy—independently releases power to the night-time load to maximize the reduction in energy charges.
Case 2: Battery SOC at 90%
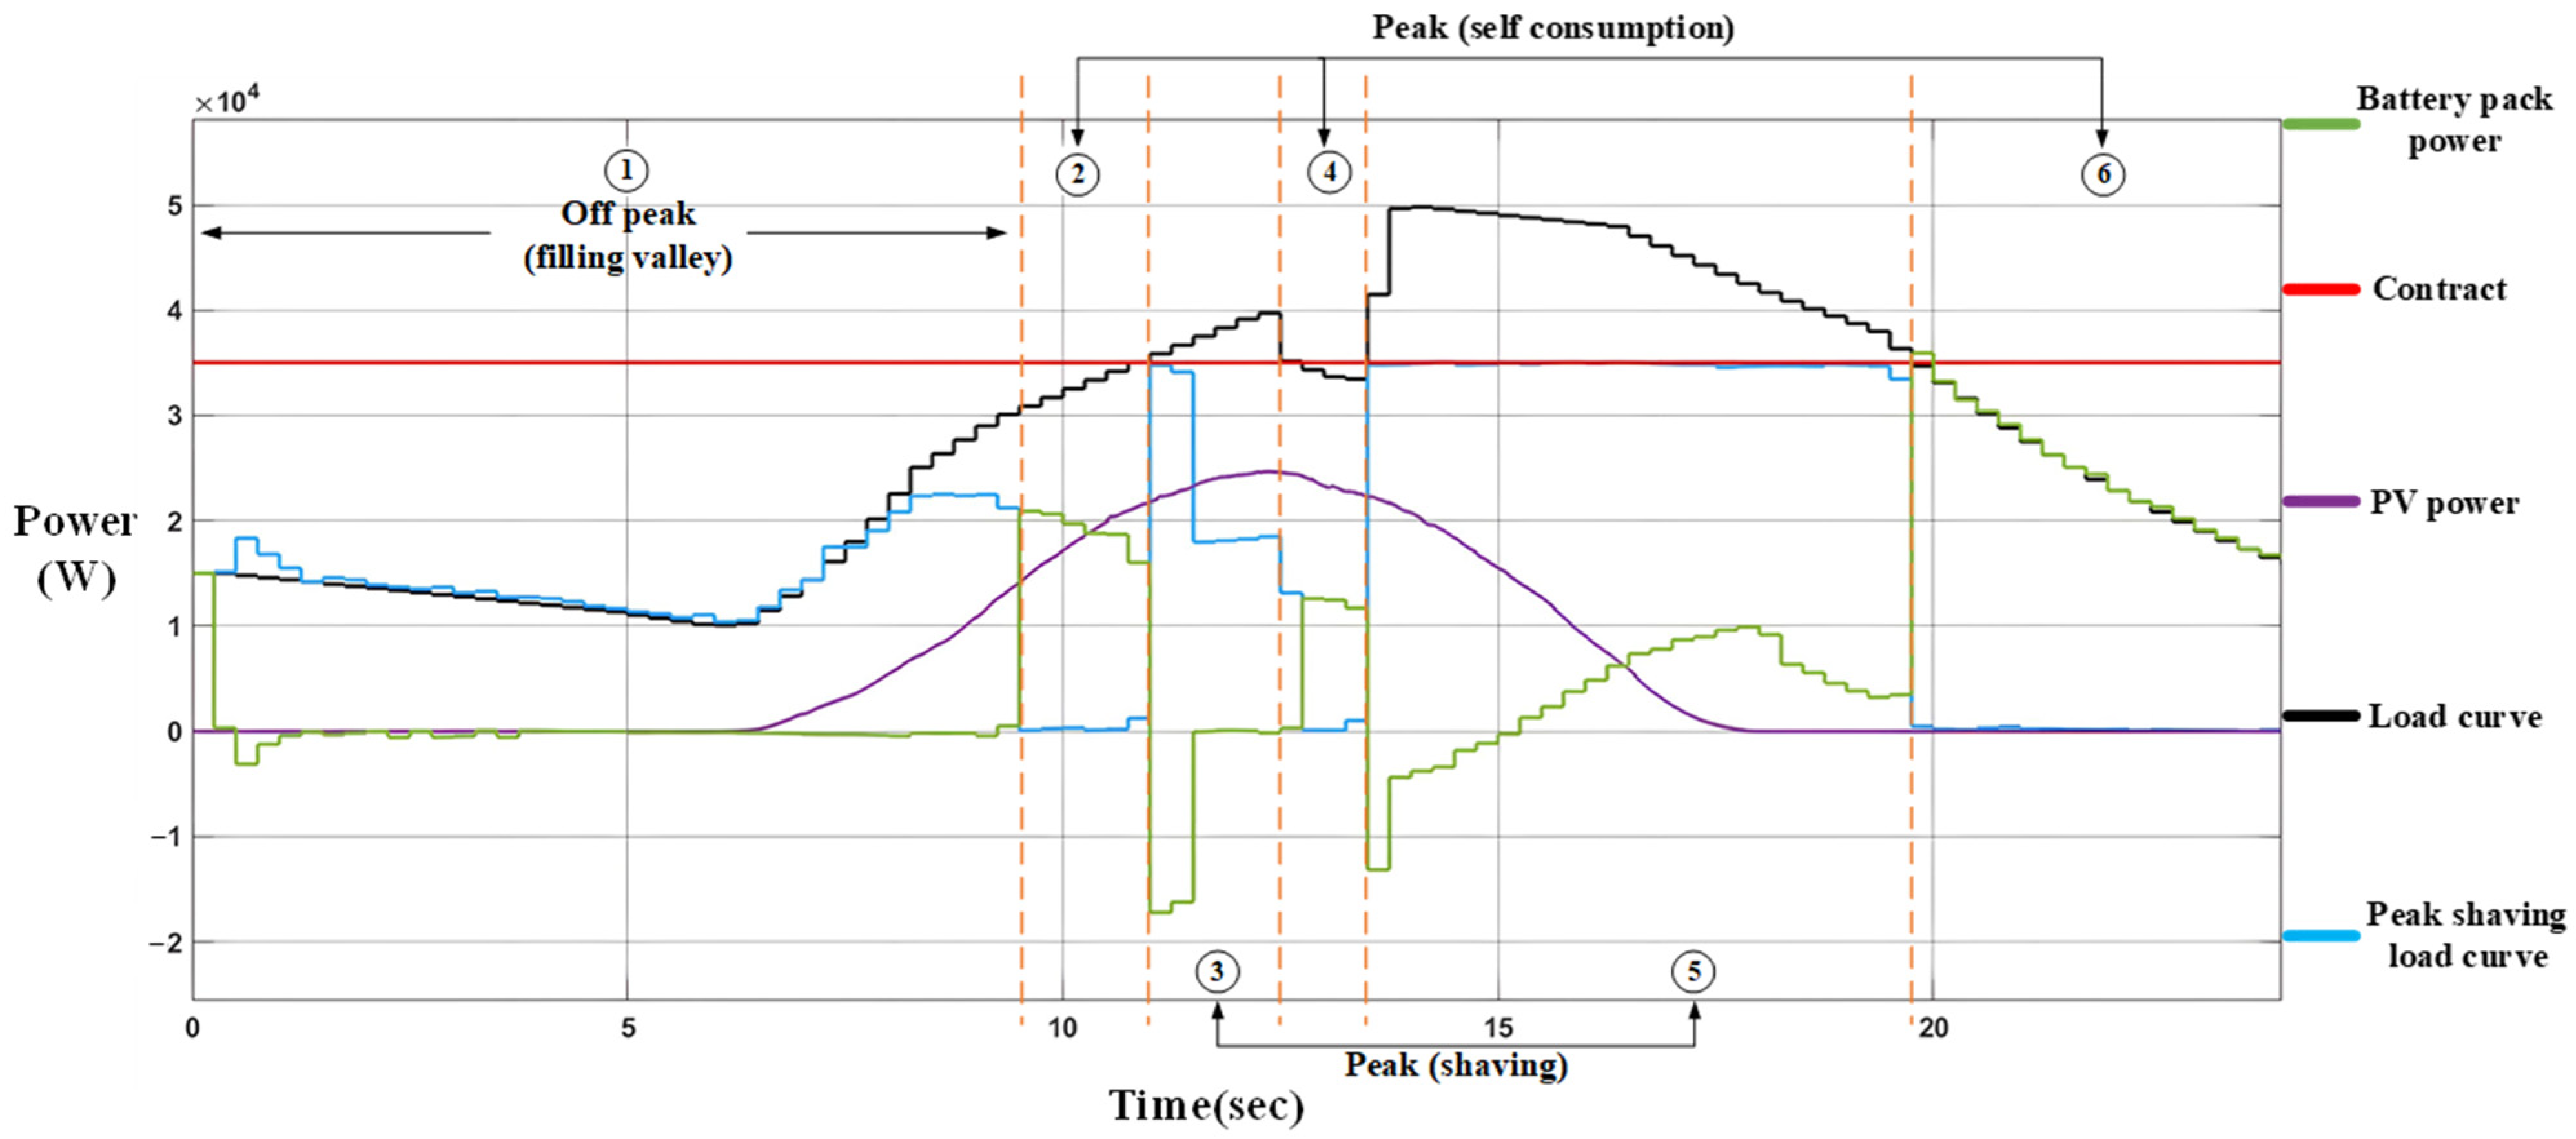
According to the daily load profile comparison of peak shaving and valley-filling control (SOC at 90%) in Figure 17, the operating conditions for Stages 2, 4, 5, and 6 are identical to those in the previous case. Therefore, the following description focuses only on Stages 1 and 3.
Figure 17.
Comparison of daily load profiles with peak shaving and valley-filling control (battery SOC at 90%).
- Stage 1
- As the lithium-iron phosphate battery pack is already in a fully charged state, the charging mode is set to constant voltage (CV) charging, with the charging current approaching zero. Compared to Case 1, since the battery pack has no charging demand, the energy generated by the PVMAs is supplied to the AC-side load via the inverter.
- Stage 3
- The inverter’s output power is controlled to shave the demand of the “first peak”. Since the maximum SOC limit in this study is set to 90% (corresponding to a terminal voltage of 311.1 V), once the battery pack is detected to have reached this threshold, the charging power instantaneously drops to zero, and the battery stops regulating the DC-link voltage. By controlling the inverter to output all energy produced by the PV module arrays, the power drawn from the grid is significantly reduced, thereby eliminating concerns regarding potential damage to the battery pack that may be caused by overcharging.
3.2.2. Simulation of the Lithium-Iron Phosphate Battery Pack Under Low SOC
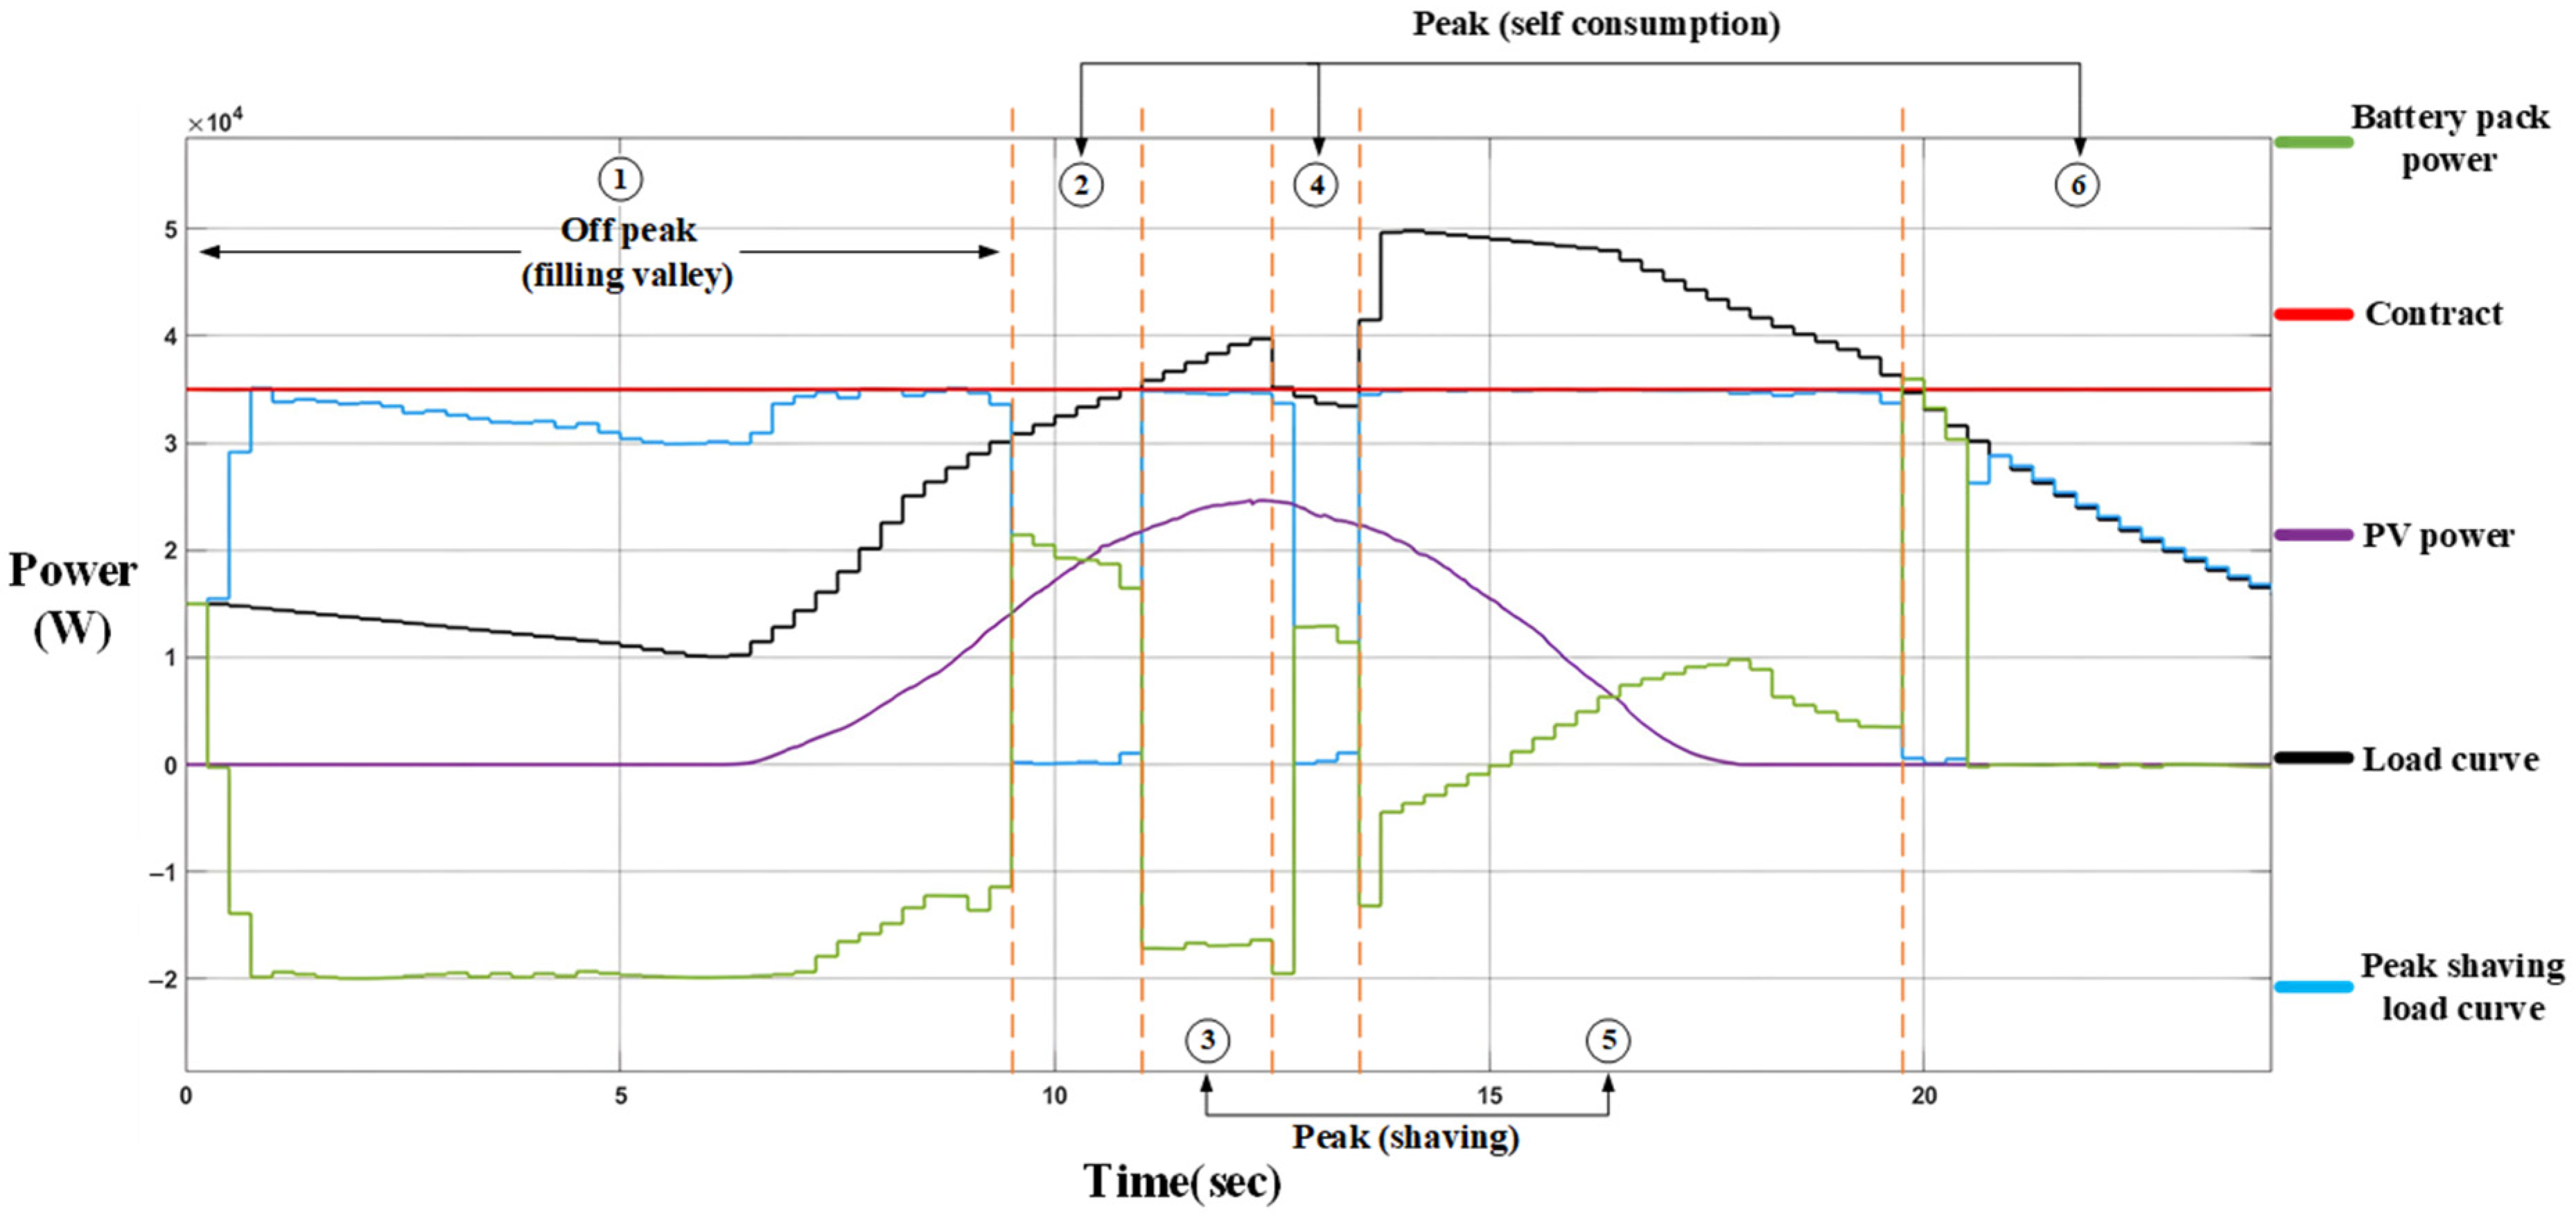
This section simulates the power control method of the proposed hybrid power system during night-time when the depth of discharge (DOD) of the lithium-iron phosphate battery pack reaches 90%. The results are presented in Figure 18, which shows the daily load profile comparison for peak shaving and valley-filling control (battery SOC at 10%). Compared to Figure 17, the operating states from Stage 1 to Stage 5 are identical. However, during Stage 6, as the system detects that the SOC has dropped to the predefined DOD threshold set at a minimum SOC of 10%, it instantaneously controls the battery pack and causes it to stop discharging. Simultaneously, since there is no power generation from the PVMAs due to the absence of solar irradiance, the utility grid supplies the entire load demand at this time.
Figure 18.
Comparison of daily load profiles with peak shaving and valley-filling control (battery SOC at 10%).
4. Experimental Results
To verify the simulation results, the proposed DC-coupled three-phase grid-connected-PV-battery system was implemented and tested using PLECS, a multi-functional power electronics simulation software developed by Plexim GmbH, in conjunction with the RT box and the analog breakout board in a Hardware-in-the-Loop (HIL) testing environment [26].
4.1. Experimental Integration of the Controller During Off-Peak Periods
Considering that battery cycle life is susceptible to charging temperatures [27], this study employs a constant current (CC) charging control at a rate of 0.2 C (65 A). This approach not only reduces the current stress on the converter but also effectively lowers the temperature of the lithium-iron phosphate battery pack, thereby extending its lifespan. However, while the battery draws power from the grid in CC charging mode, a heavy AC-side load may cause the total grid supply to exceed the contract capacity. Therefore, this section describes the experimental results of the battery charging control under both high and low AC-side load demands.
4.1.1. Case 1: Low Load Demand
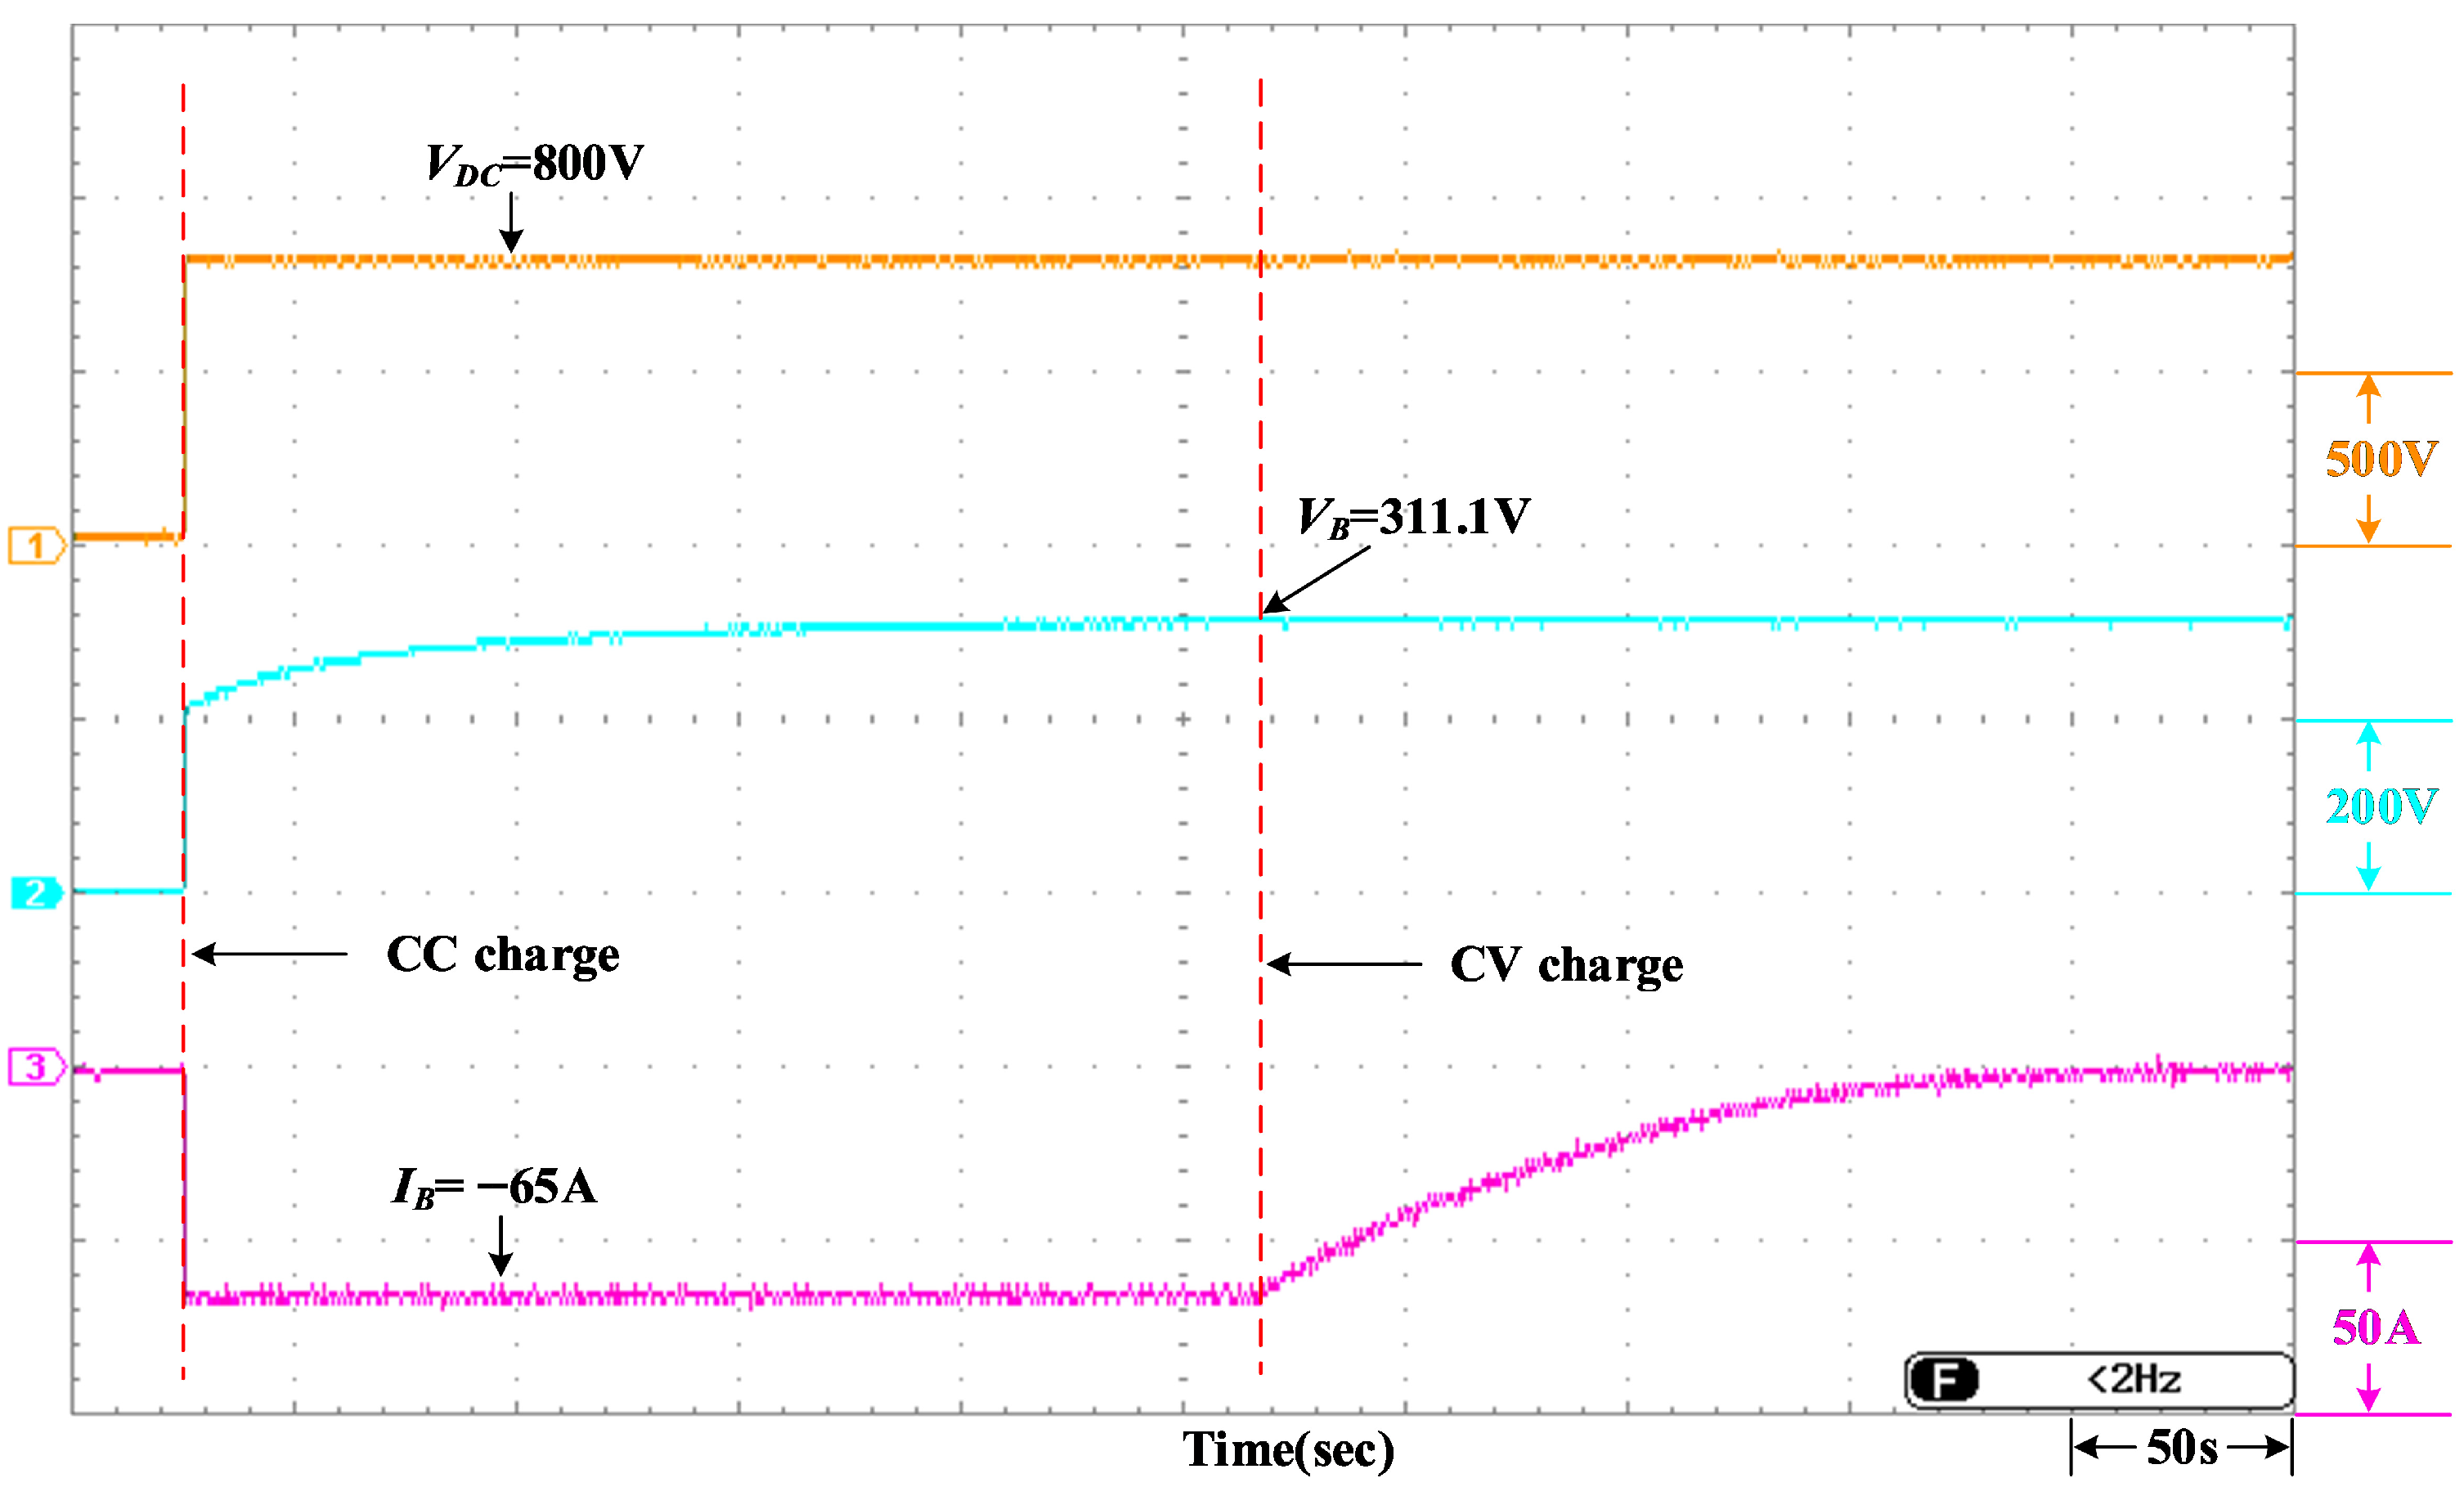
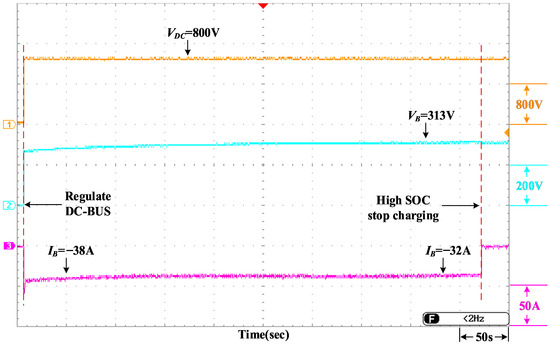
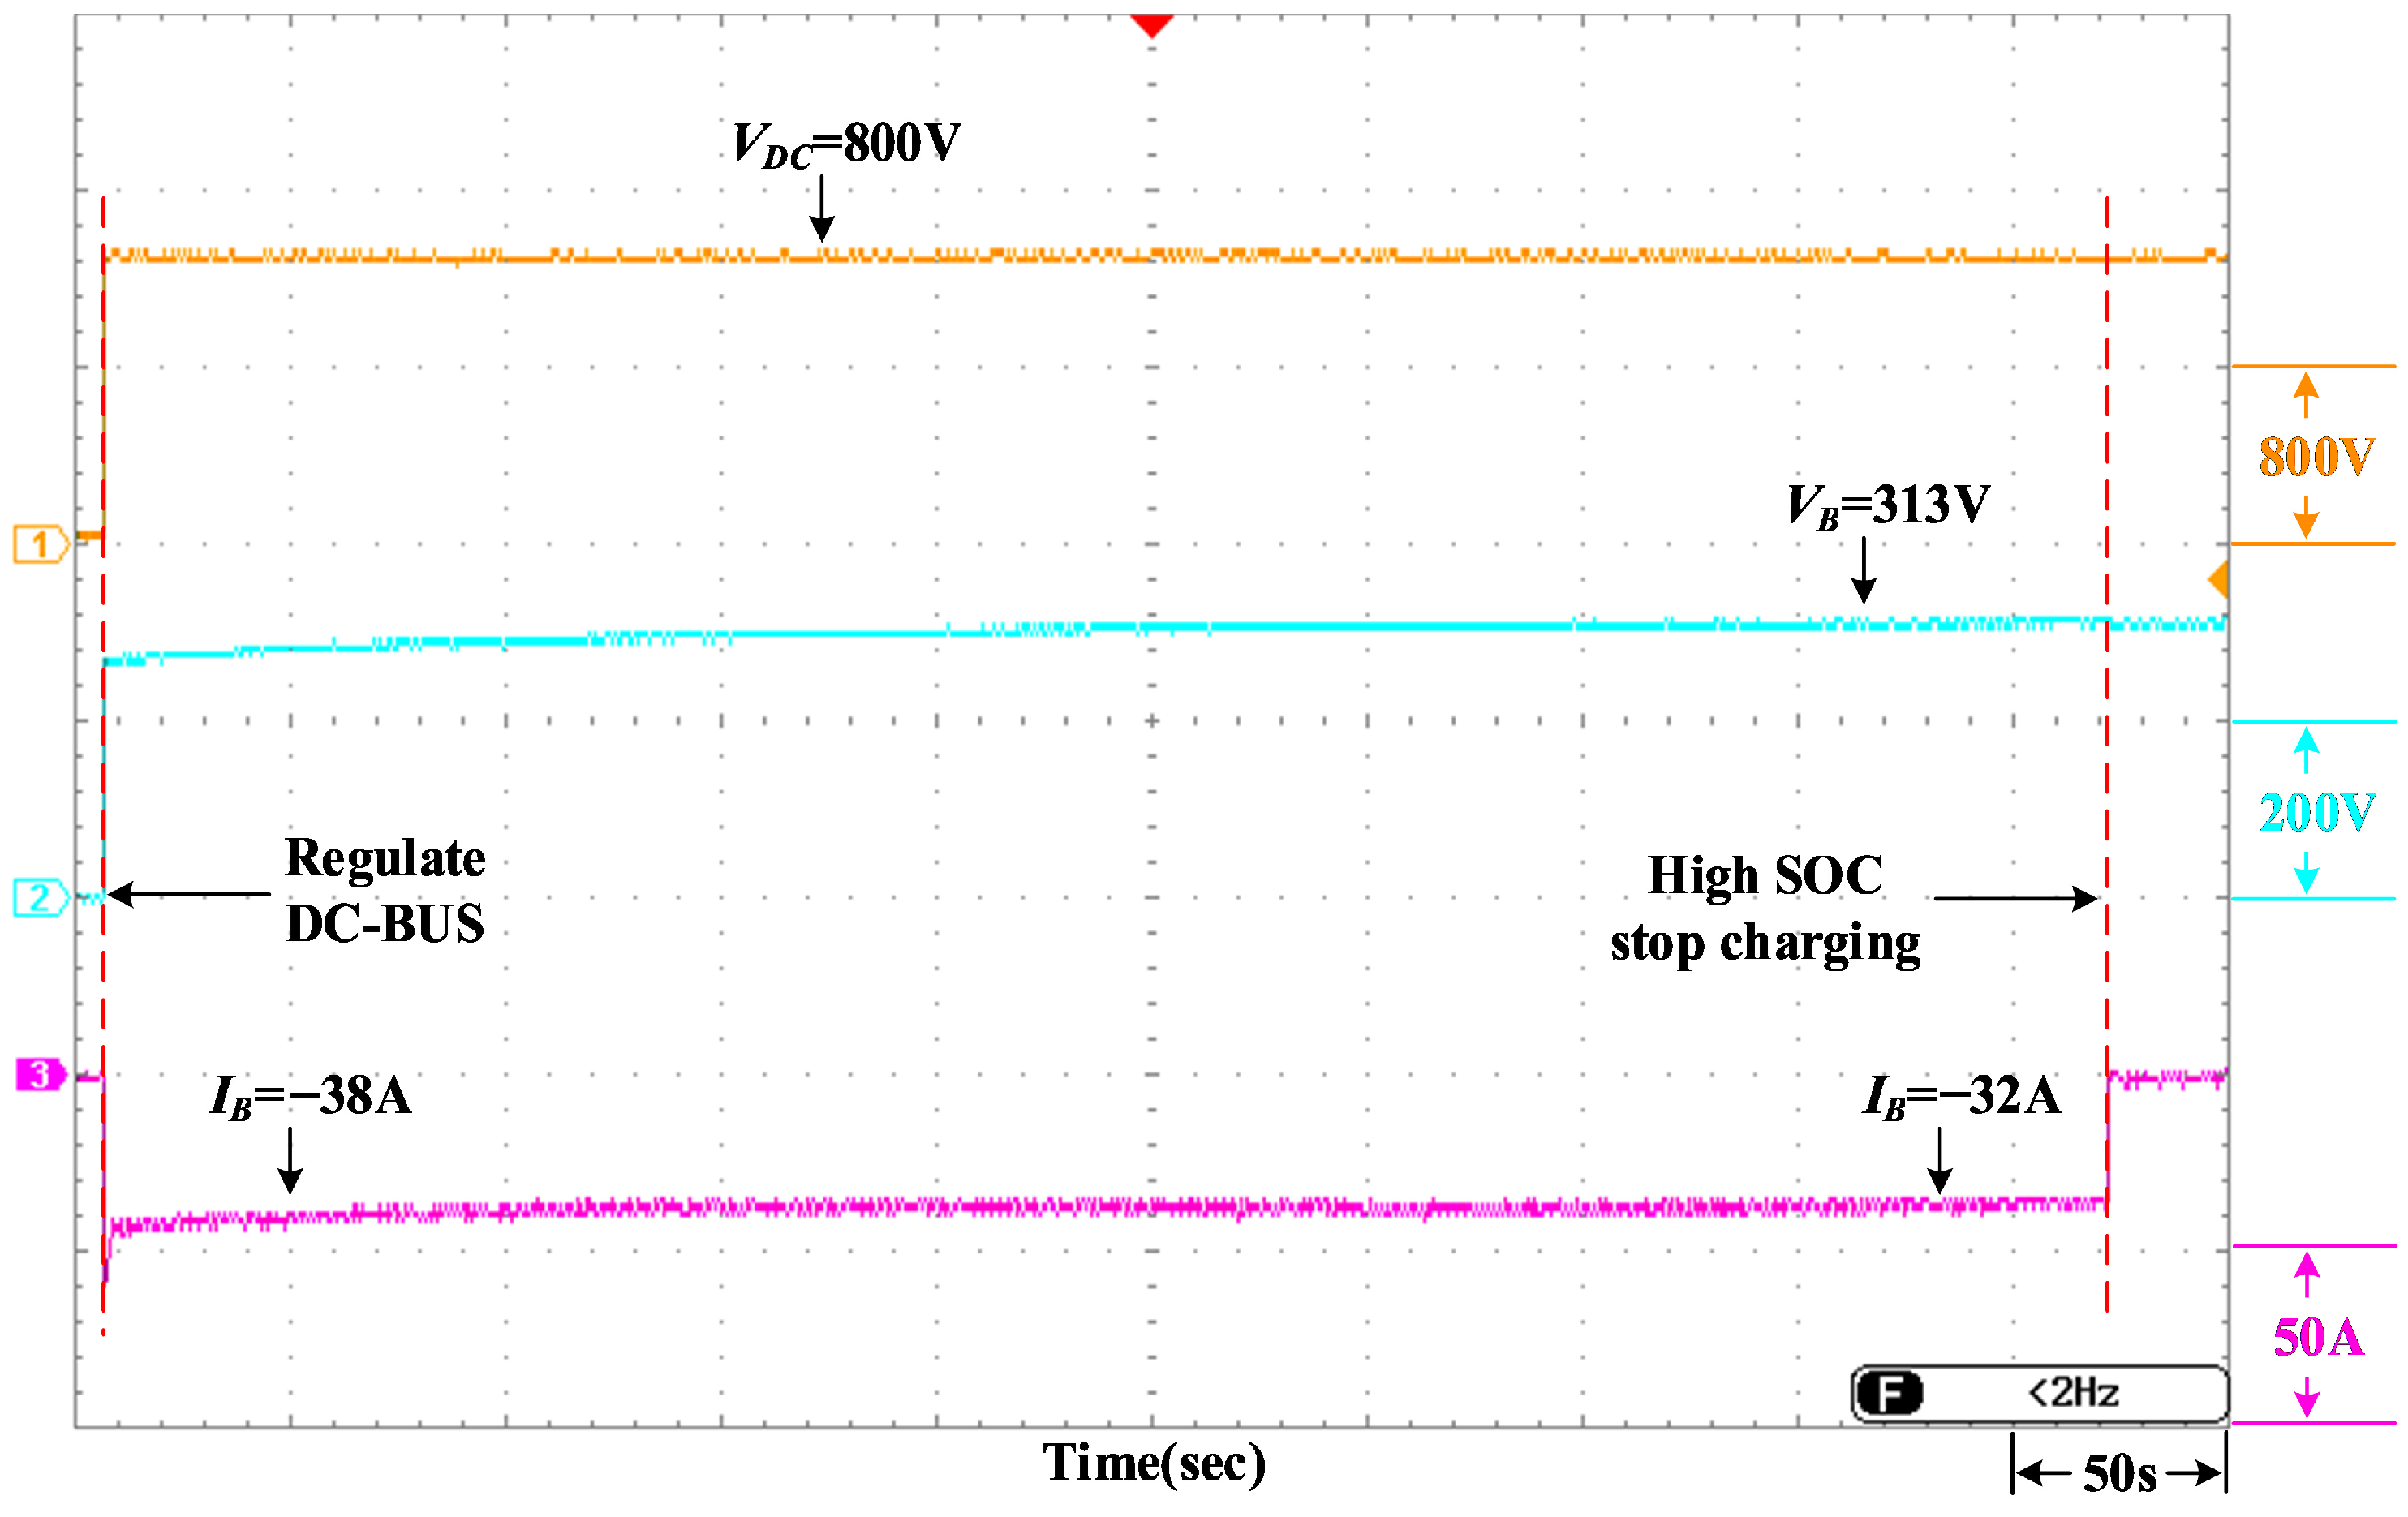
When the sum of the battery charging demand and the AC-side load demand does not exceed the contract capacity, the battery pack adopts the CC-CV charging mode, as shown in Figure 19. It can be observed from the figure that the DC-link voltage is rectified and regulated at 800 V by the smart inverter. This allows the bidirectional buck-boost converter to operate stably in buck mode while supplying power to the battery. During the CC charging process, the battery terminal voltage rises continuously. Once the voltage reaches 311.1 V (the terminal voltage corresponding to a 90% SOC), the charging mode switches to the predefined constant voltage (CV). At this stage, the charging current decreases as the SOC increases. After the SOC reaches 90%, the charging current approaches zero, and the battery pack enters a float charging state with a minimal current.
Figure 19.
Battery charging response using the CC-CV controller at 10% SOC.
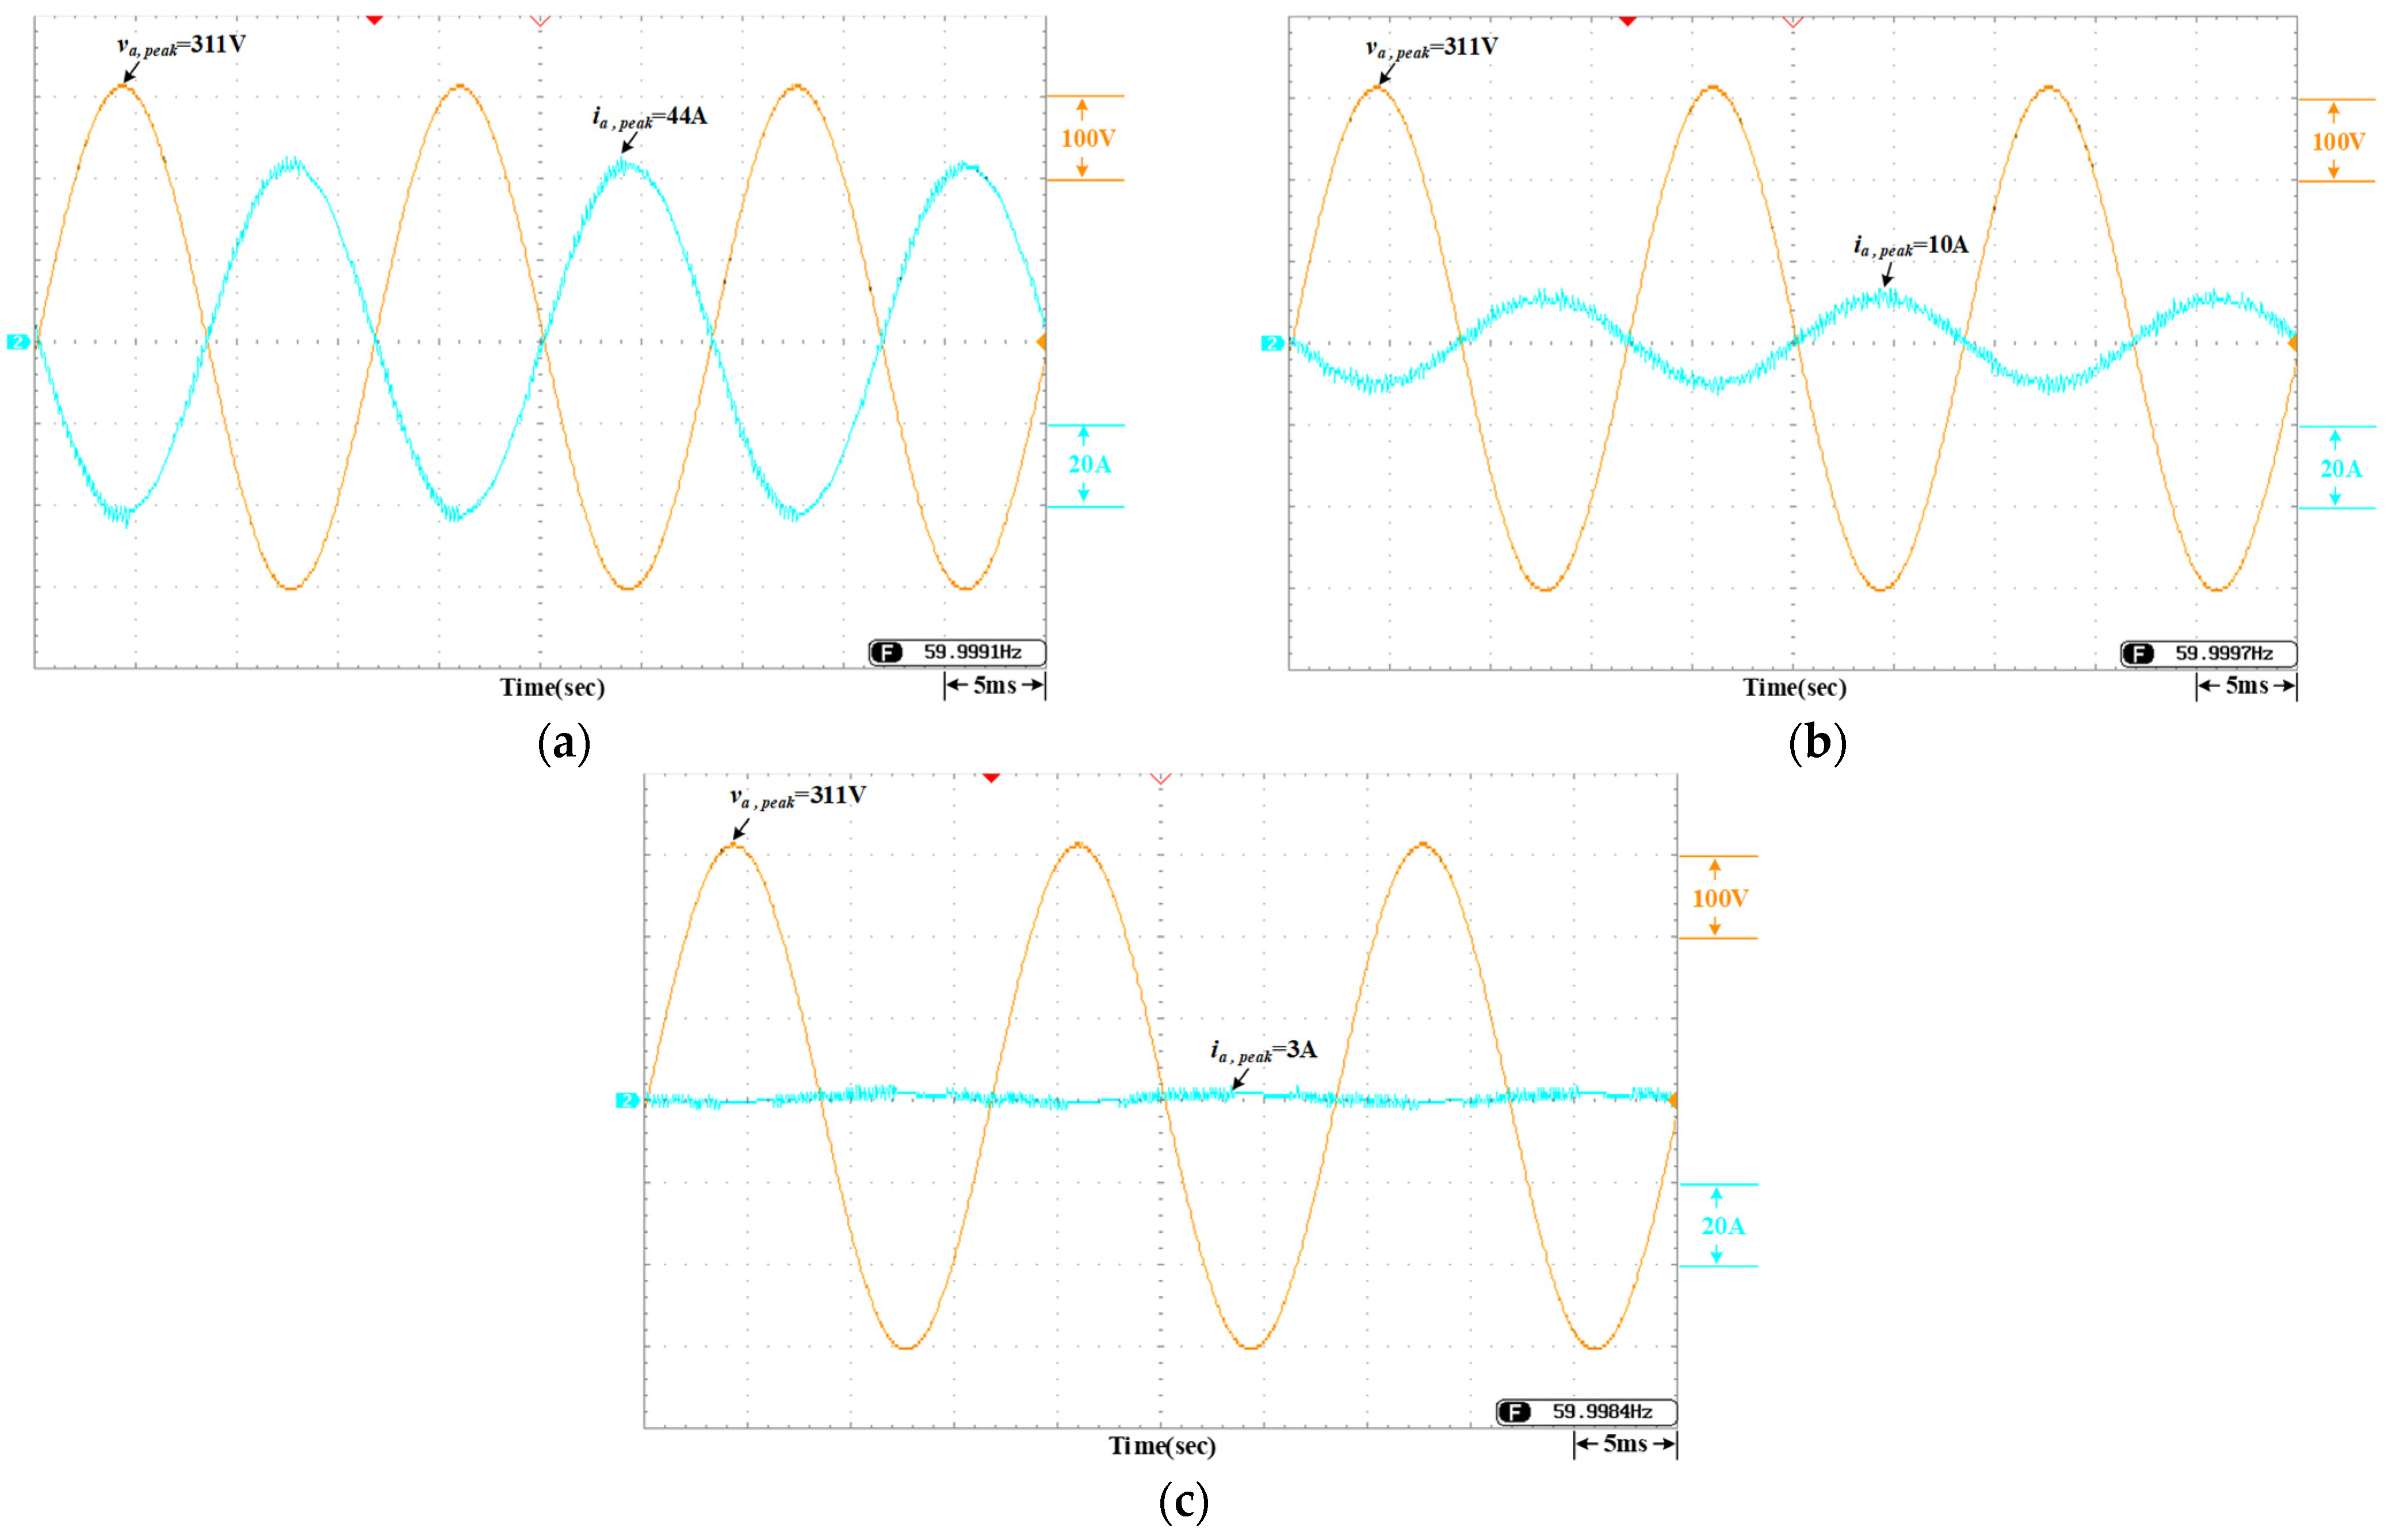
During the CC-CV charging process of the lithium-iron phosphate battery pack, the supply current from the utility grid varies in accordance with the battery pack’s charging current. To verify that the hysteresis current control employed by the smart inverter can perform PFC and reduce the THD of the current across different battery SOC levels, the phase voltages and currents of the three-phase system were measured. Figure 20 shows the measured voltage and current waveforms of the inverter using hysteresis current control. Since the inverter absorbs energy from the grid to supply the DC side, the voltage and current waveforms are 180° out of phase. Based on the experimental measurements, the power factor (PF) is stably maintained above 0.99, and the total harmonic distortion (THD) of the grid currents is strictly controlled below 5%, fully complying with grid-connection standards.
Figure 20.
Measured voltage and current waveforms of the inverter using hysteresis current control: (a) battery SOC 10–75%; (b) battery SOC 85%; (c) battery SOC 90%.
4.1.2. Case 2: High Load Demand
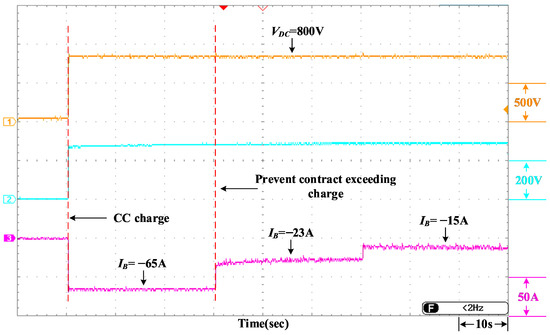
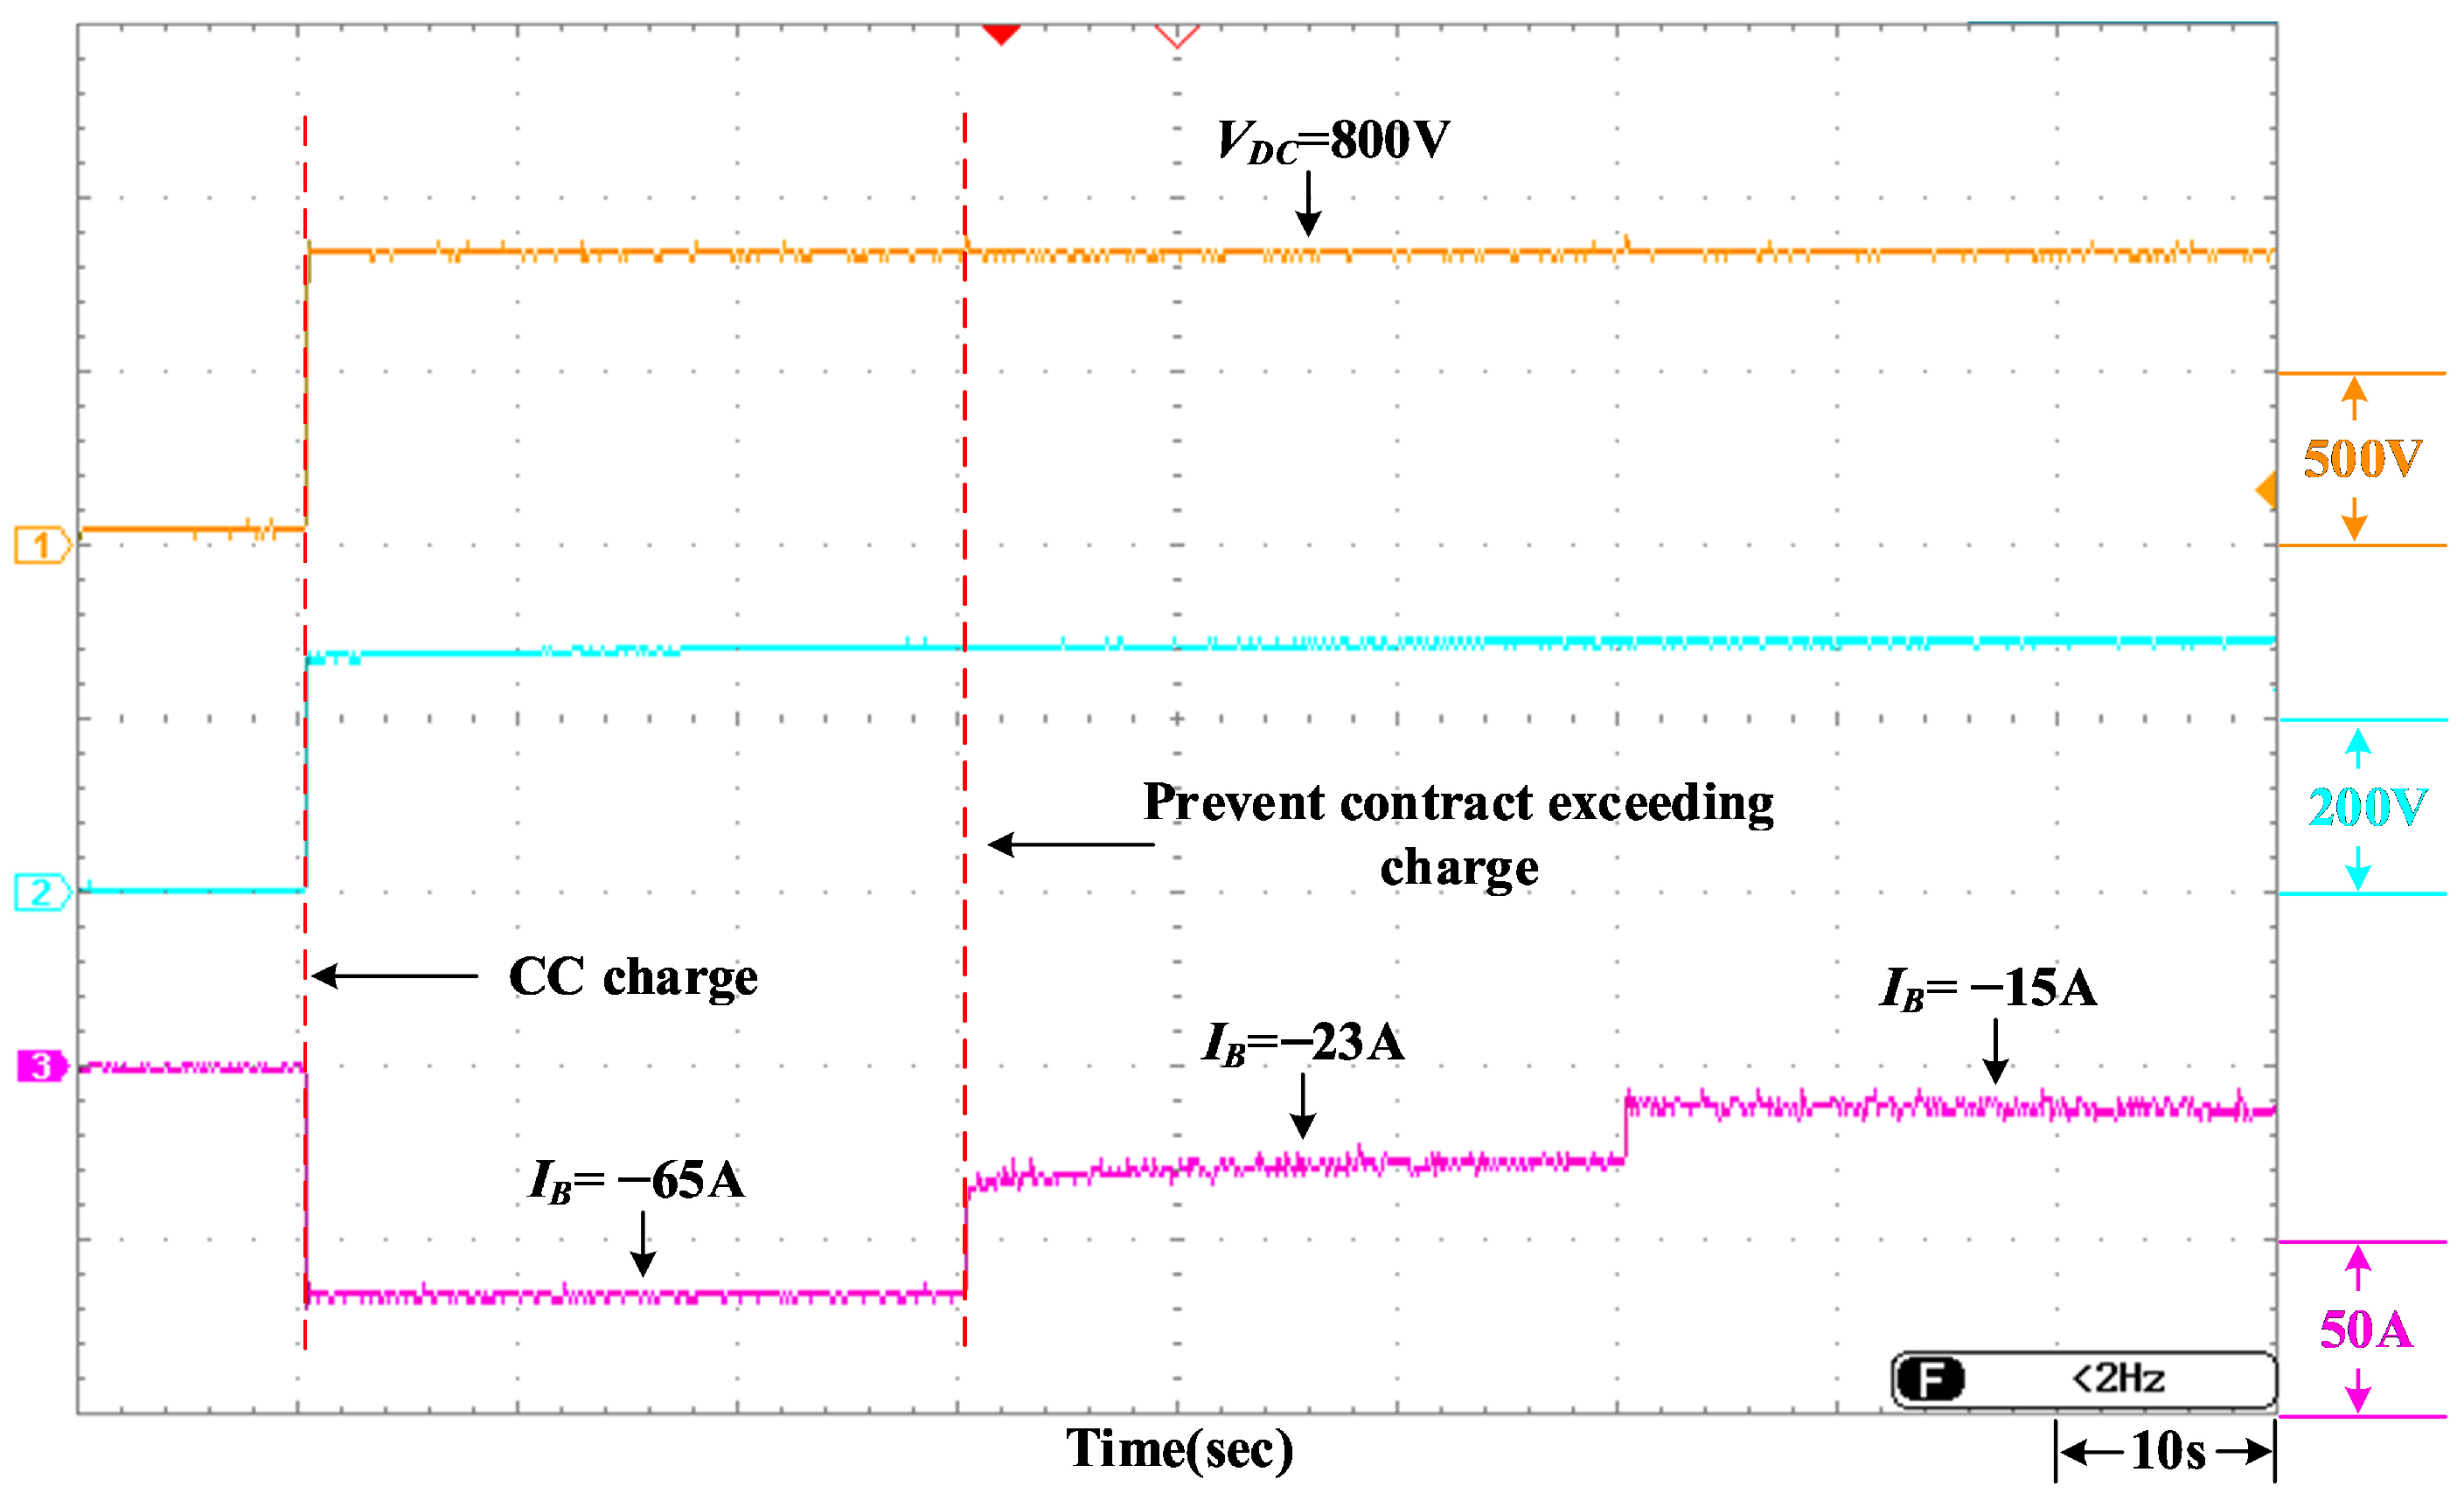
When the total power demand from the lithium-iron phosphate battery charging and the AC-side load exceeds the contract capacity, the battery pack enters the prevention-of-over-contract charging mode. The experimental results are shown in Figure 21. It can be observed that in the initial stage of the hybrid power system operation, the battery is charged at a constant current of 0.2 C (65 A). As the AC-side load demand suddenly rises, the charging current is decreased rapidly. Due to the short transient response time (settling time < 5 ms), the battery charging current quickly stabilizes back to a steady state with a minimal current ripple.
Figure 21.
Measured battery charging response under prevention-of-over-contract charging mode.
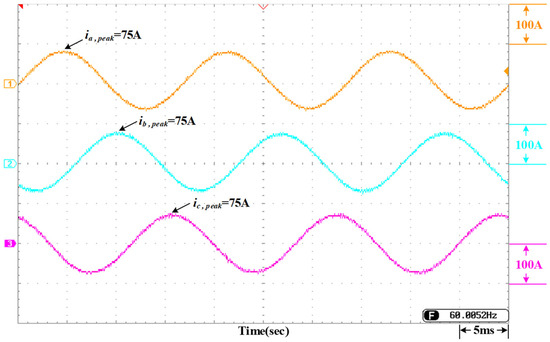
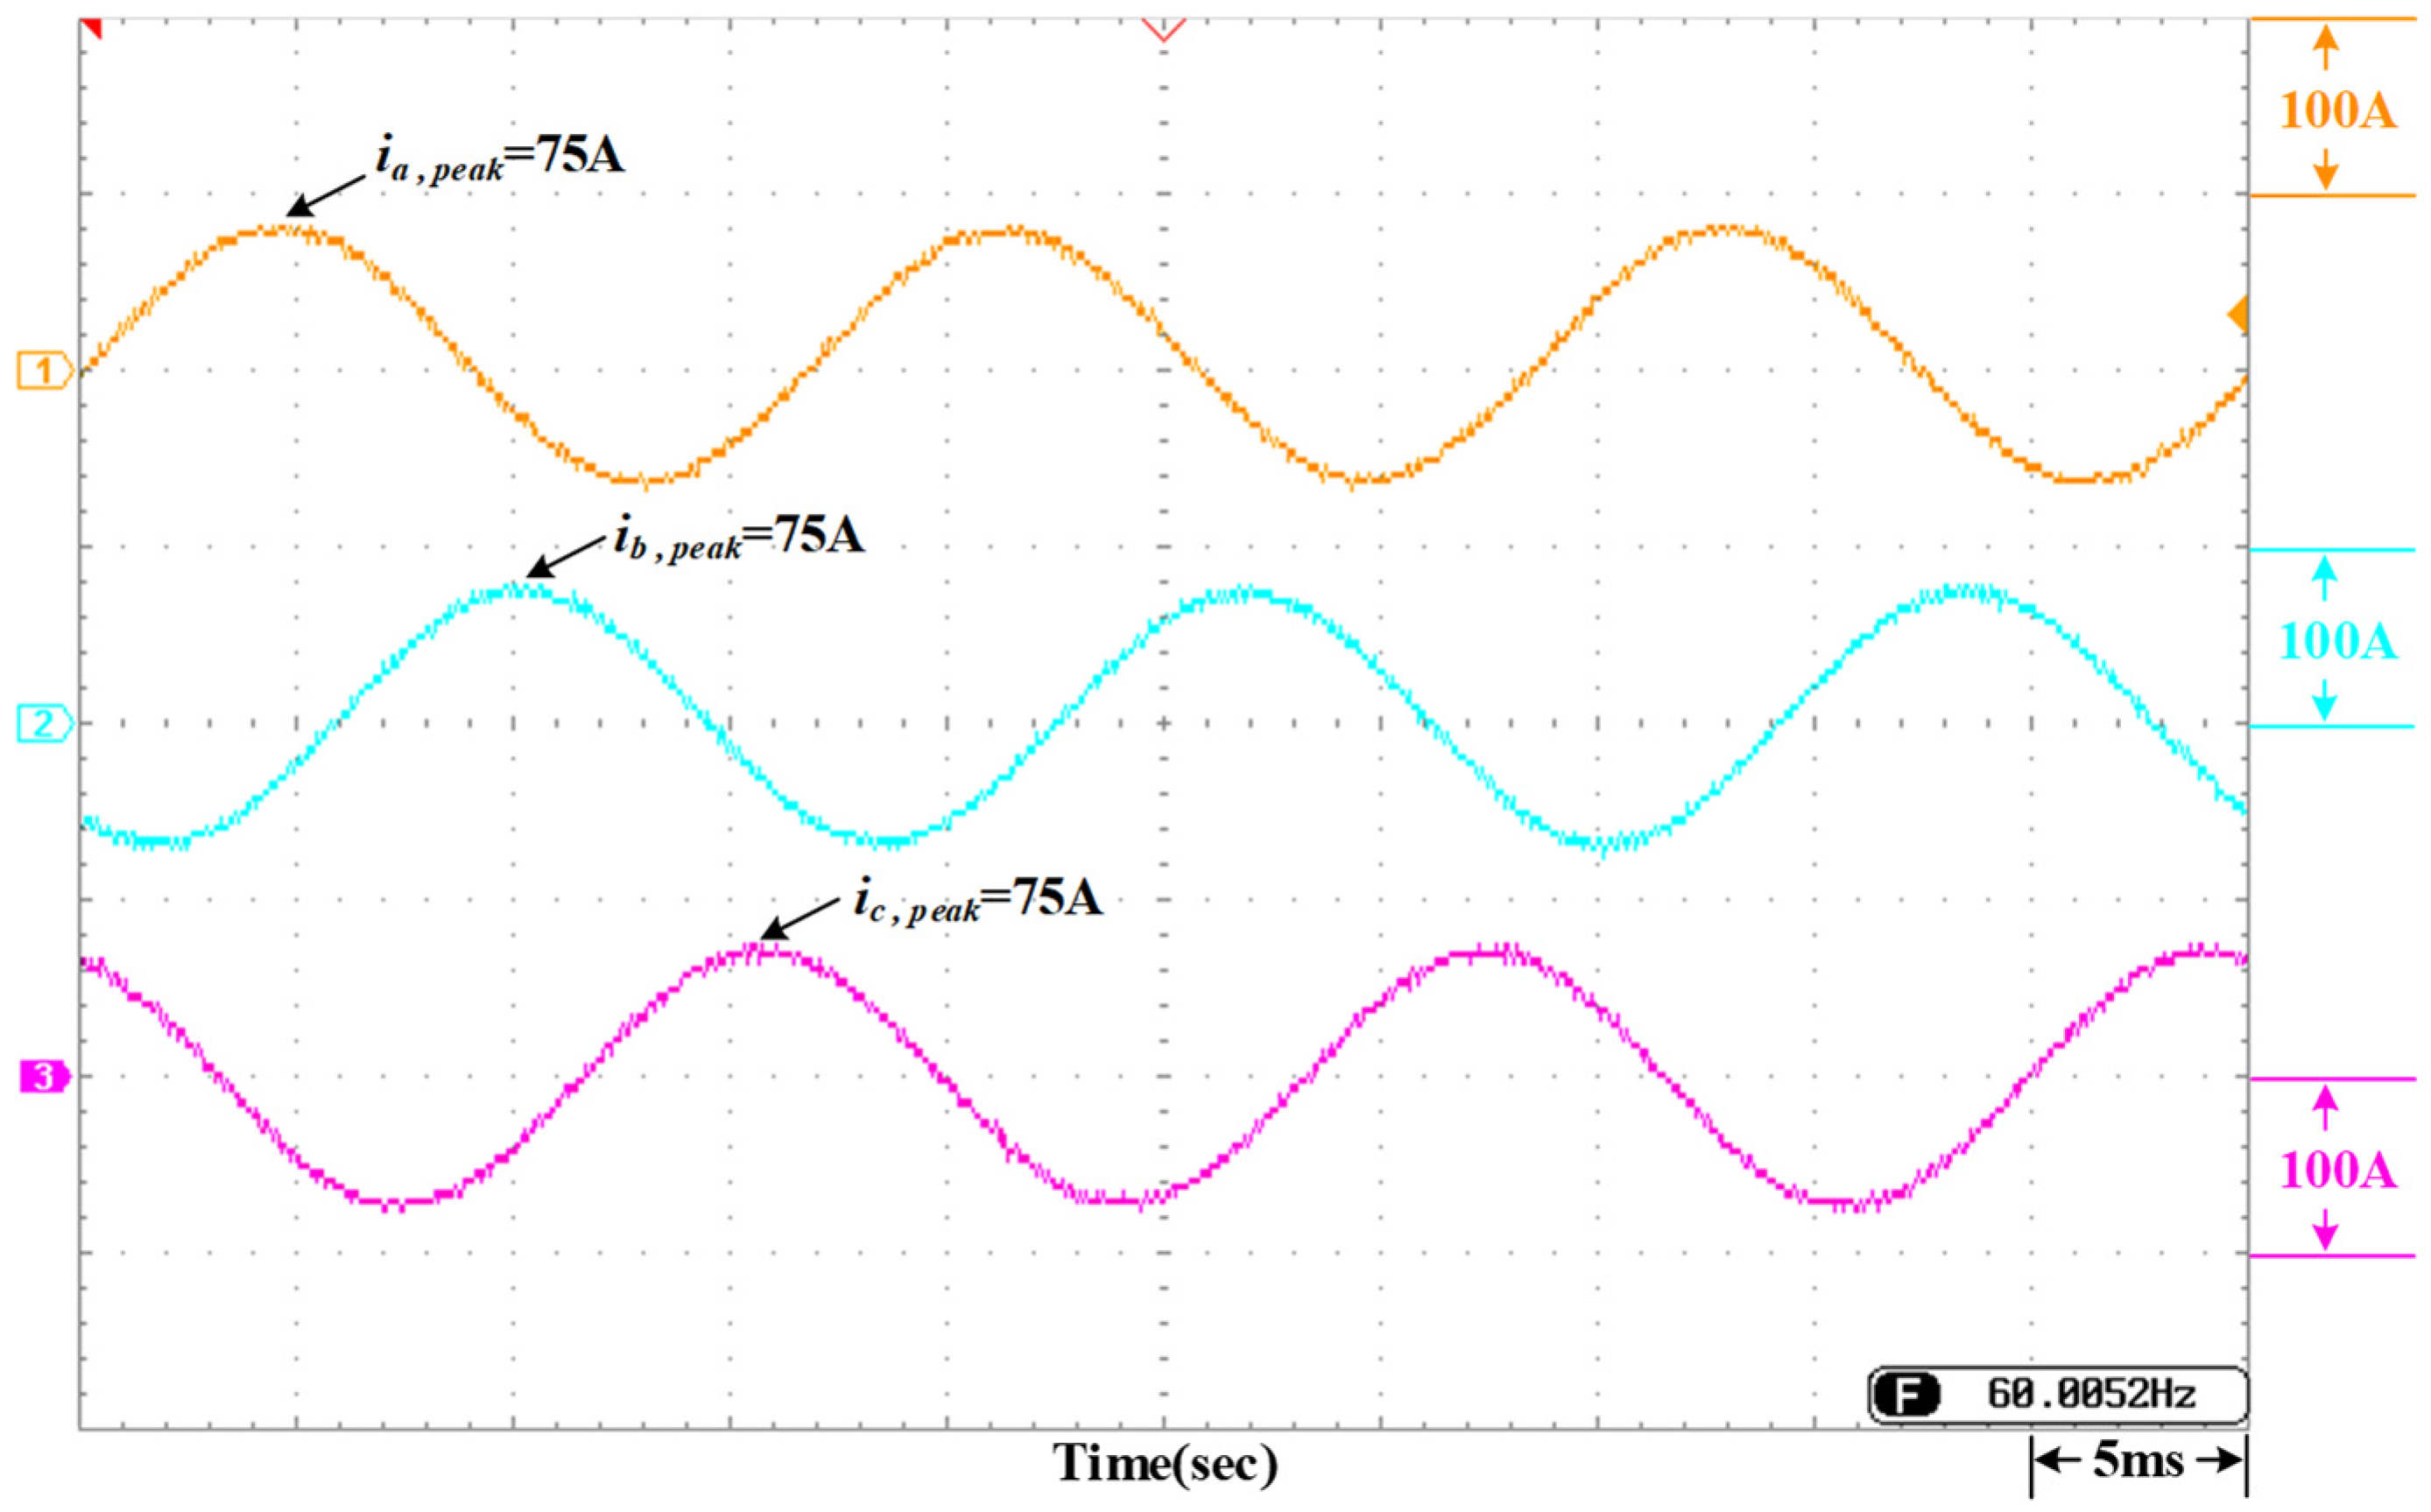
The hysteresis current control employed by the smart inverter successfully stabilizes the DC-link voltage at the predefined setpoint of 800 V with a voltage ripple tightly bounded within 1%, even as the battery charging current decreases. Simultaneously, it maintains the grid supply power within the contract capacity limits. During this period, the supply current from the grid is regulated at 75 A. Calculations using Equation (10) verify that the grid supply power is 35 kW, which aligns with the contract capacity value established in this study. The measured results for the grid are illustrated in Figure 22.
Figure 22.
Measured grid-side output current waveforms under over-contract prevention control.
4.2. Experimental Integration of the Controller During Peak Periods
When the smart inverter and the lithium-iron phosphate battery pack perform peak clipping during peak electricity demand periods, excessive or insufficient loads will cause the battery pack to regulate DC-link voltages that are either too high or too low. Consequently, the battery pack may encounter scenarios where the DC-link voltage is excessively high while the battery remains fully charged, or where the DC-link voltage is too low while the battery’s SOC is also insufficient.
In response to these conditions, this section describes the experimental results for two specific cases, utilizing the proposed integrated controller architecture as explained below.
4.2.1. Case 1: Excessive DC-Link Voltage with Battery SOC at 90%
This scenario occurs when the power generation from the PVMAs exceeds the current power demand of the smart inverter, leading to a rise in the DC-link voltage. Once the battery pack detects that the DC-link voltage is higher than the setpoint, it begins to absorb the excess energy from the DC link. However, since the battery’s SOC has reached 90%, it can no longer continue to regulate the DC-link voltage and must immediately stop charging. The measured results for the DC-link voltage, battery terminal voltage, and battery current are shown in Figure 23.
Figure 23.
Measured results of DC-link voltage, battery terminal voltage, and current for Case 1 during peak periods.
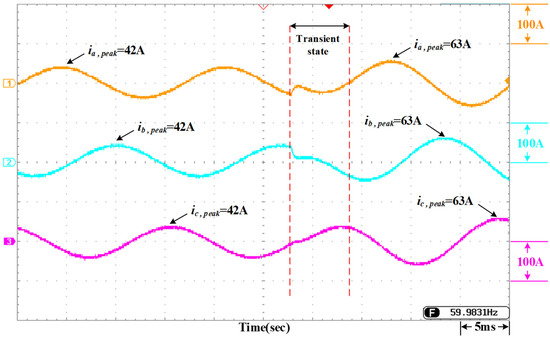
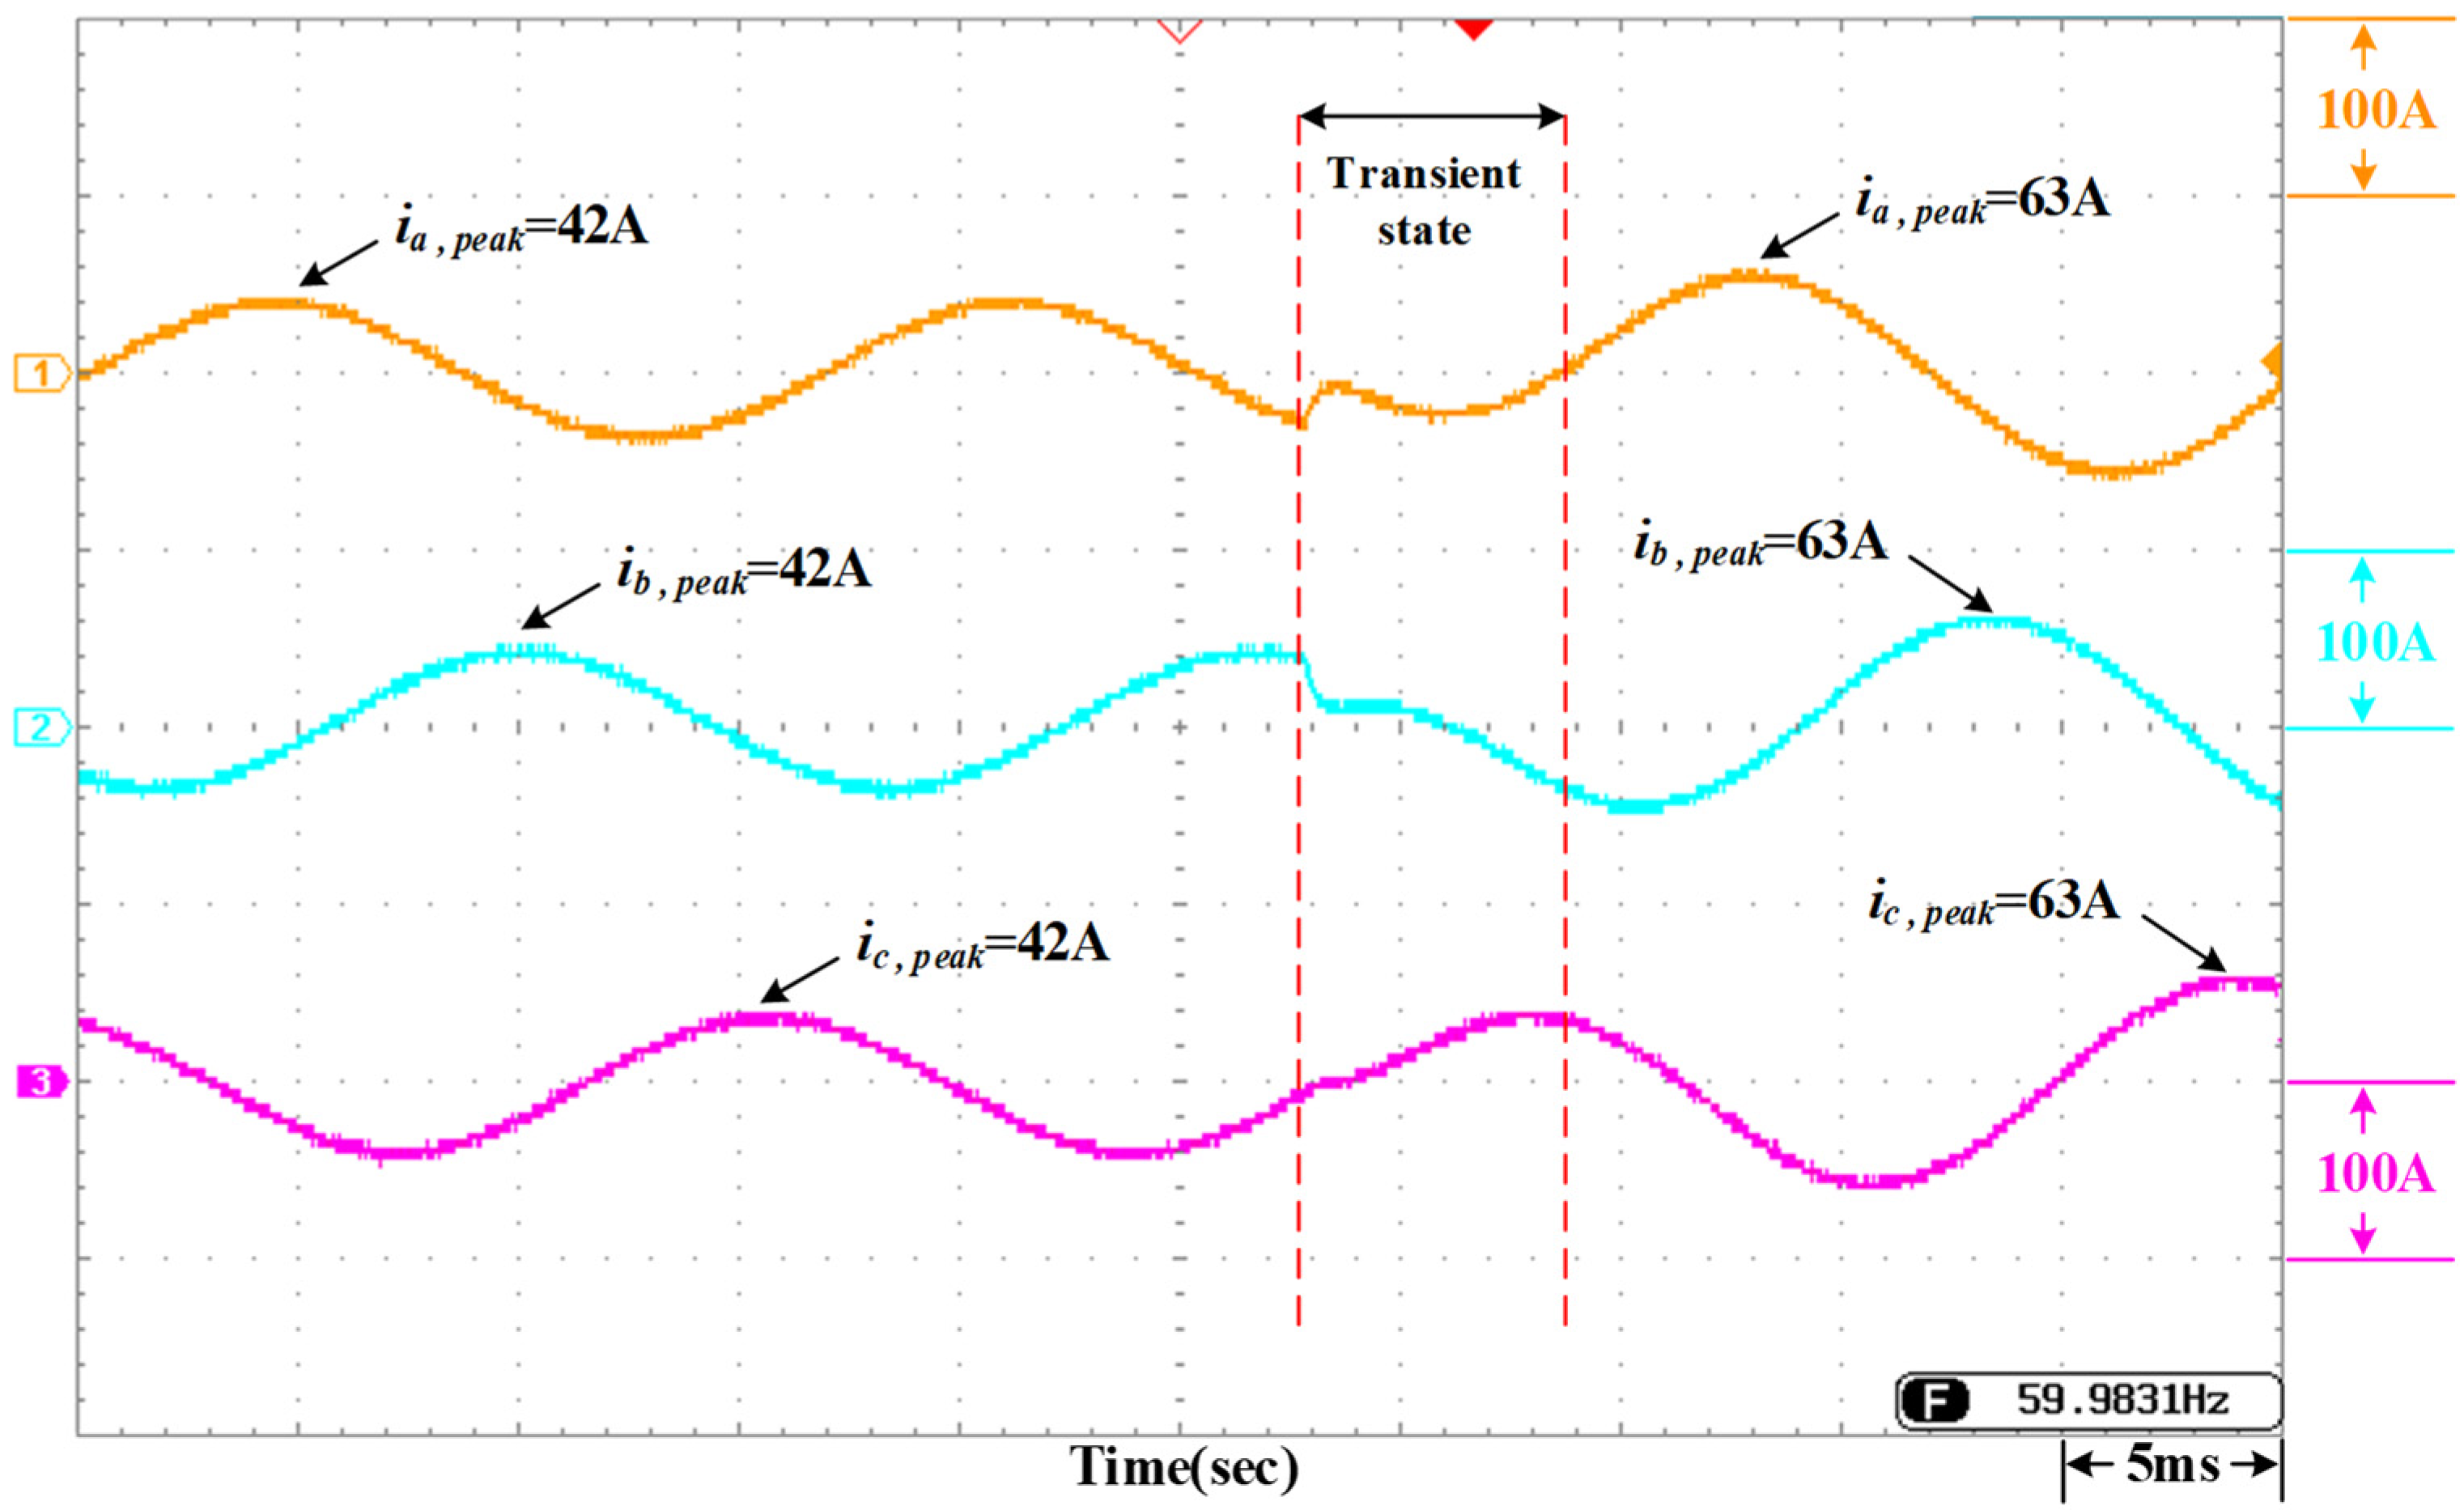
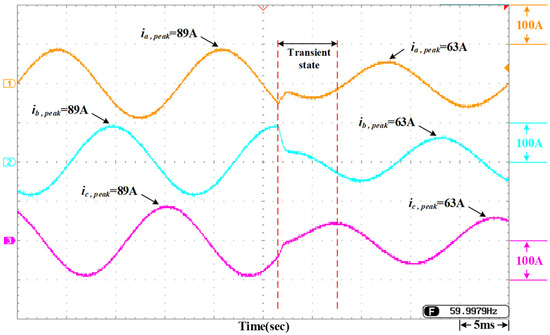
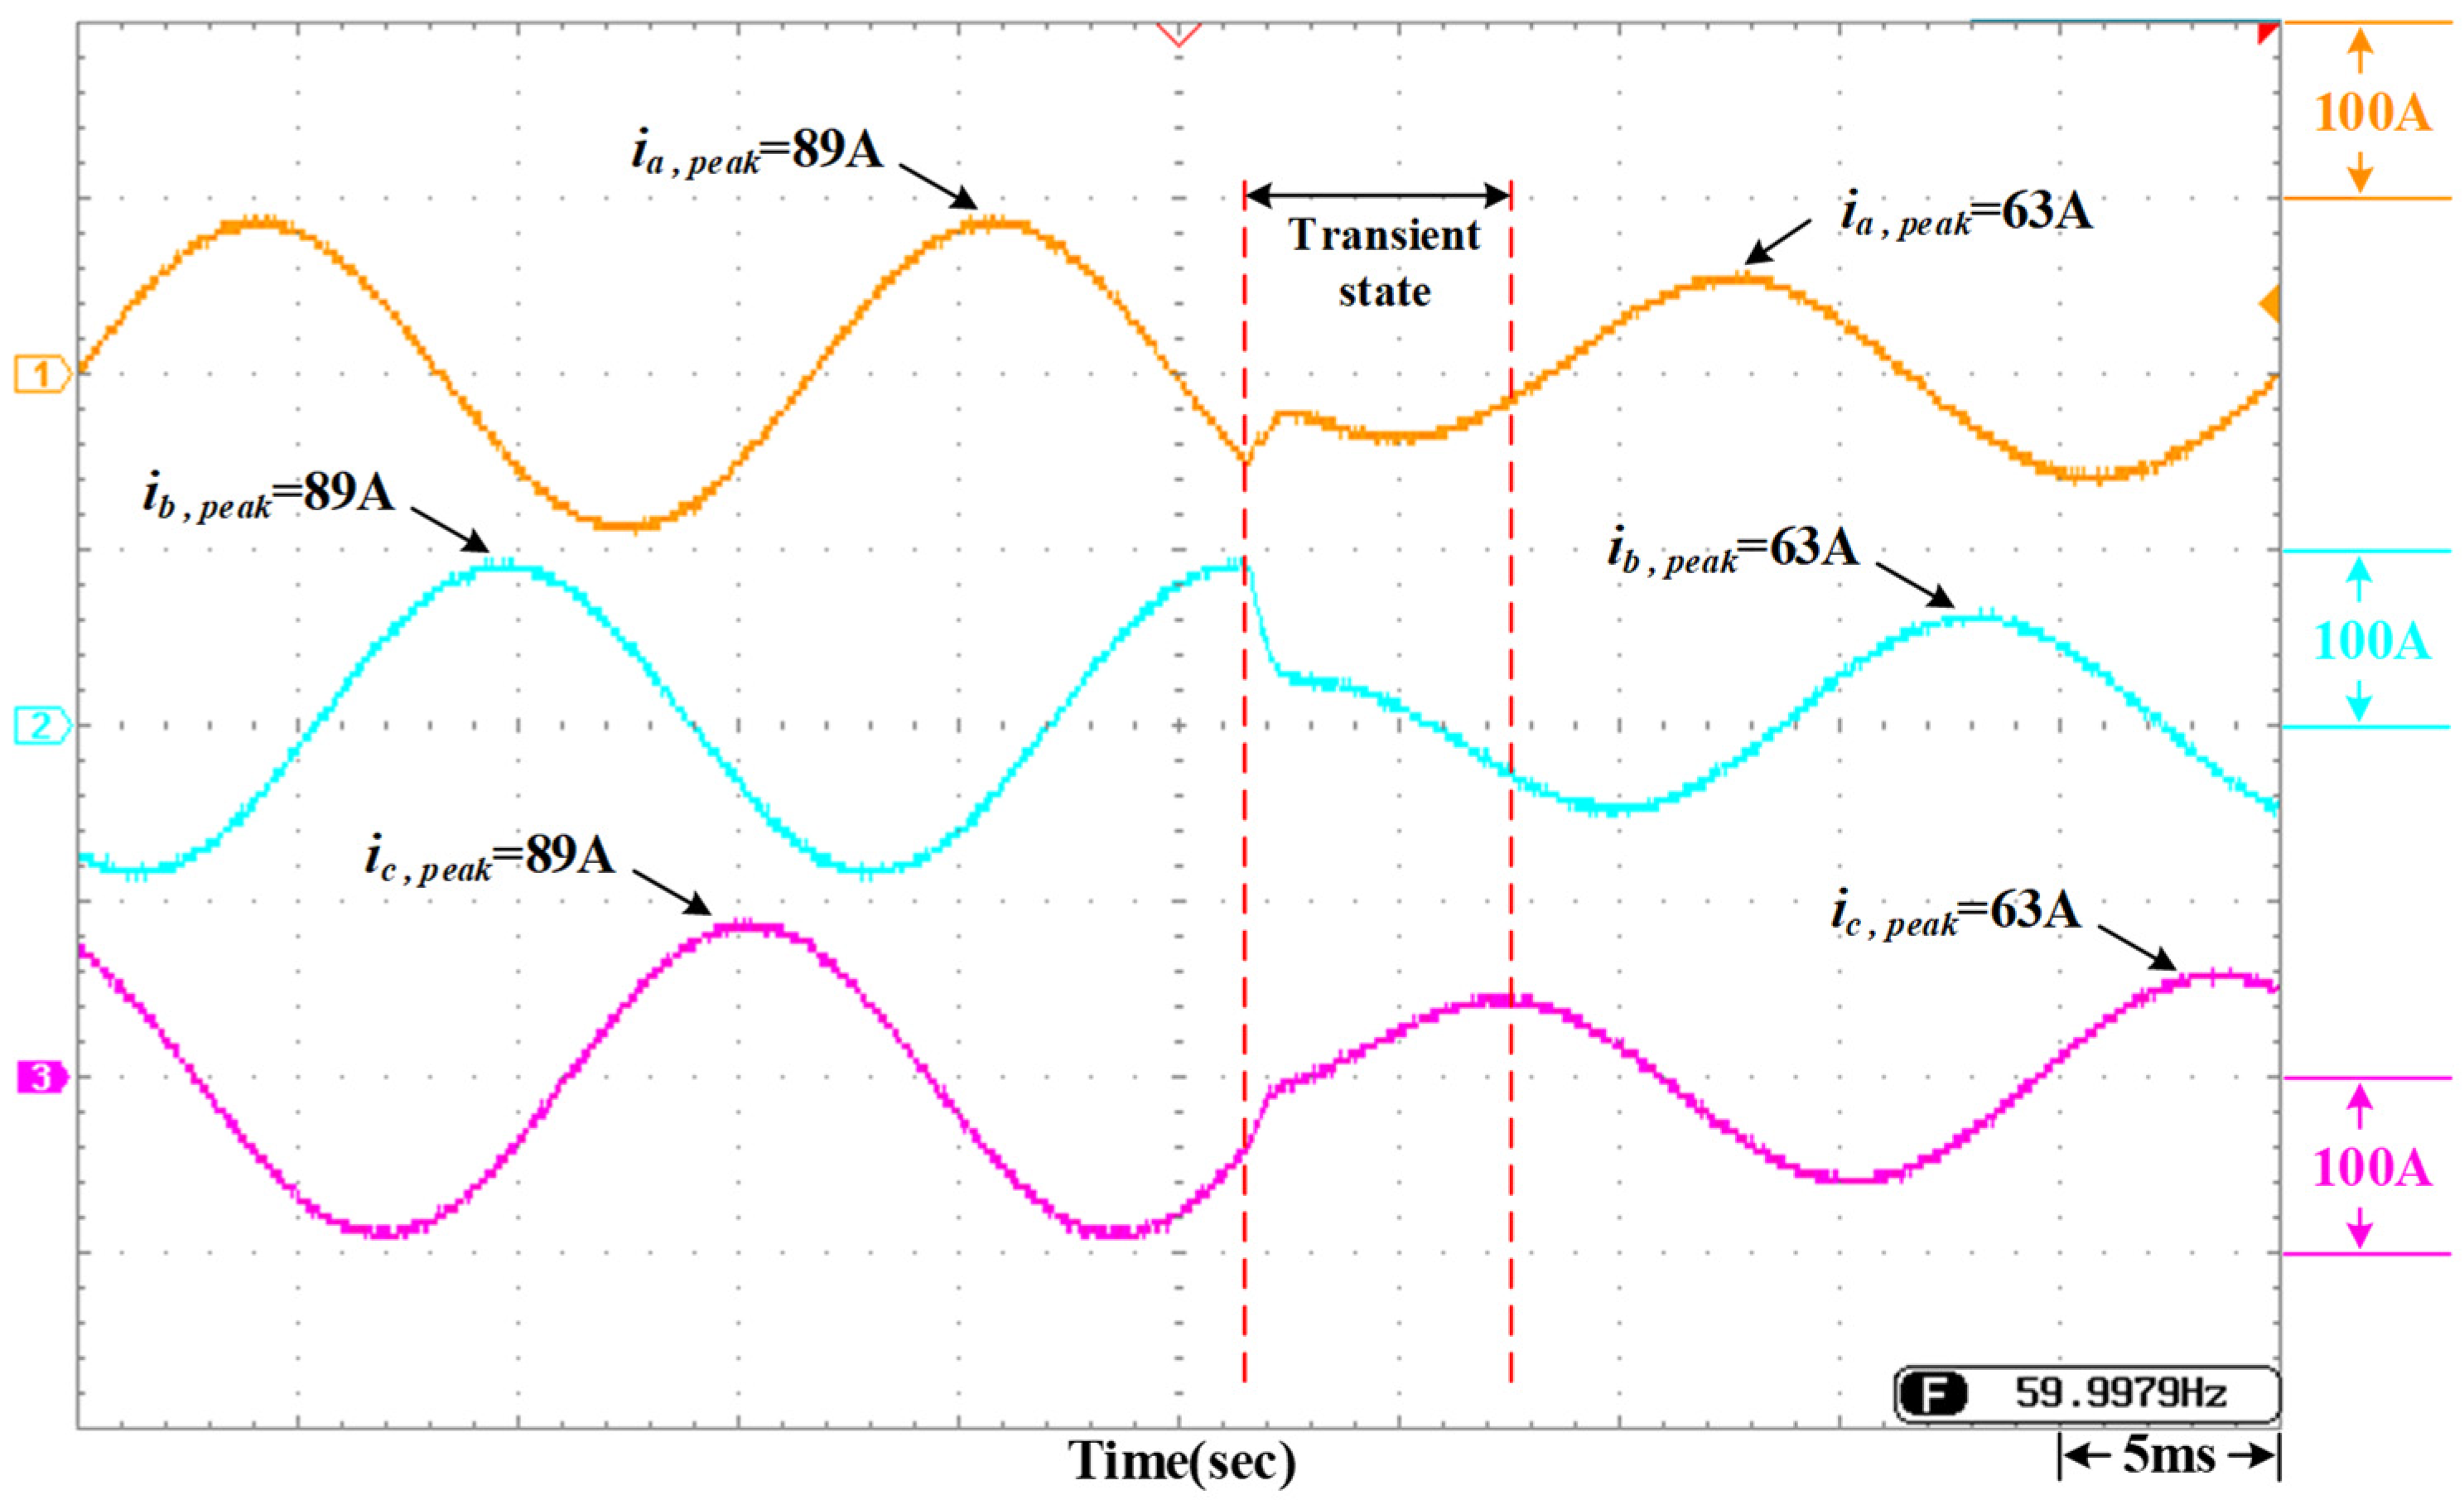
Under this condition, according to the measured output current waveforms of the smart inverter in Figure 24, it can be observed that while the lithium-iron phosphate battery pack absorbs energy from the DC link, the inverter simultaneously outputs current to the AC-side load. Once the battery pack can no longer absorb energy, the inverter outputs all the electrical energy generated by the PVMA to the AC side, causing its output current to increase.
Figure 24.
Measured output current waveforms of the smart inverter for Case 1 during peak periods.
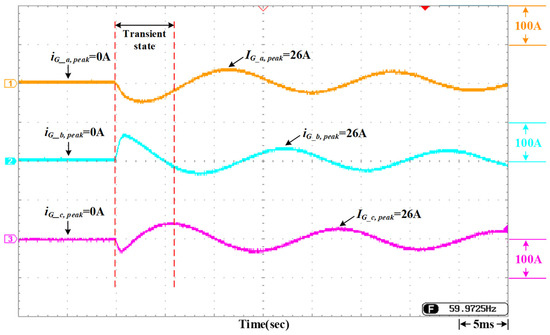
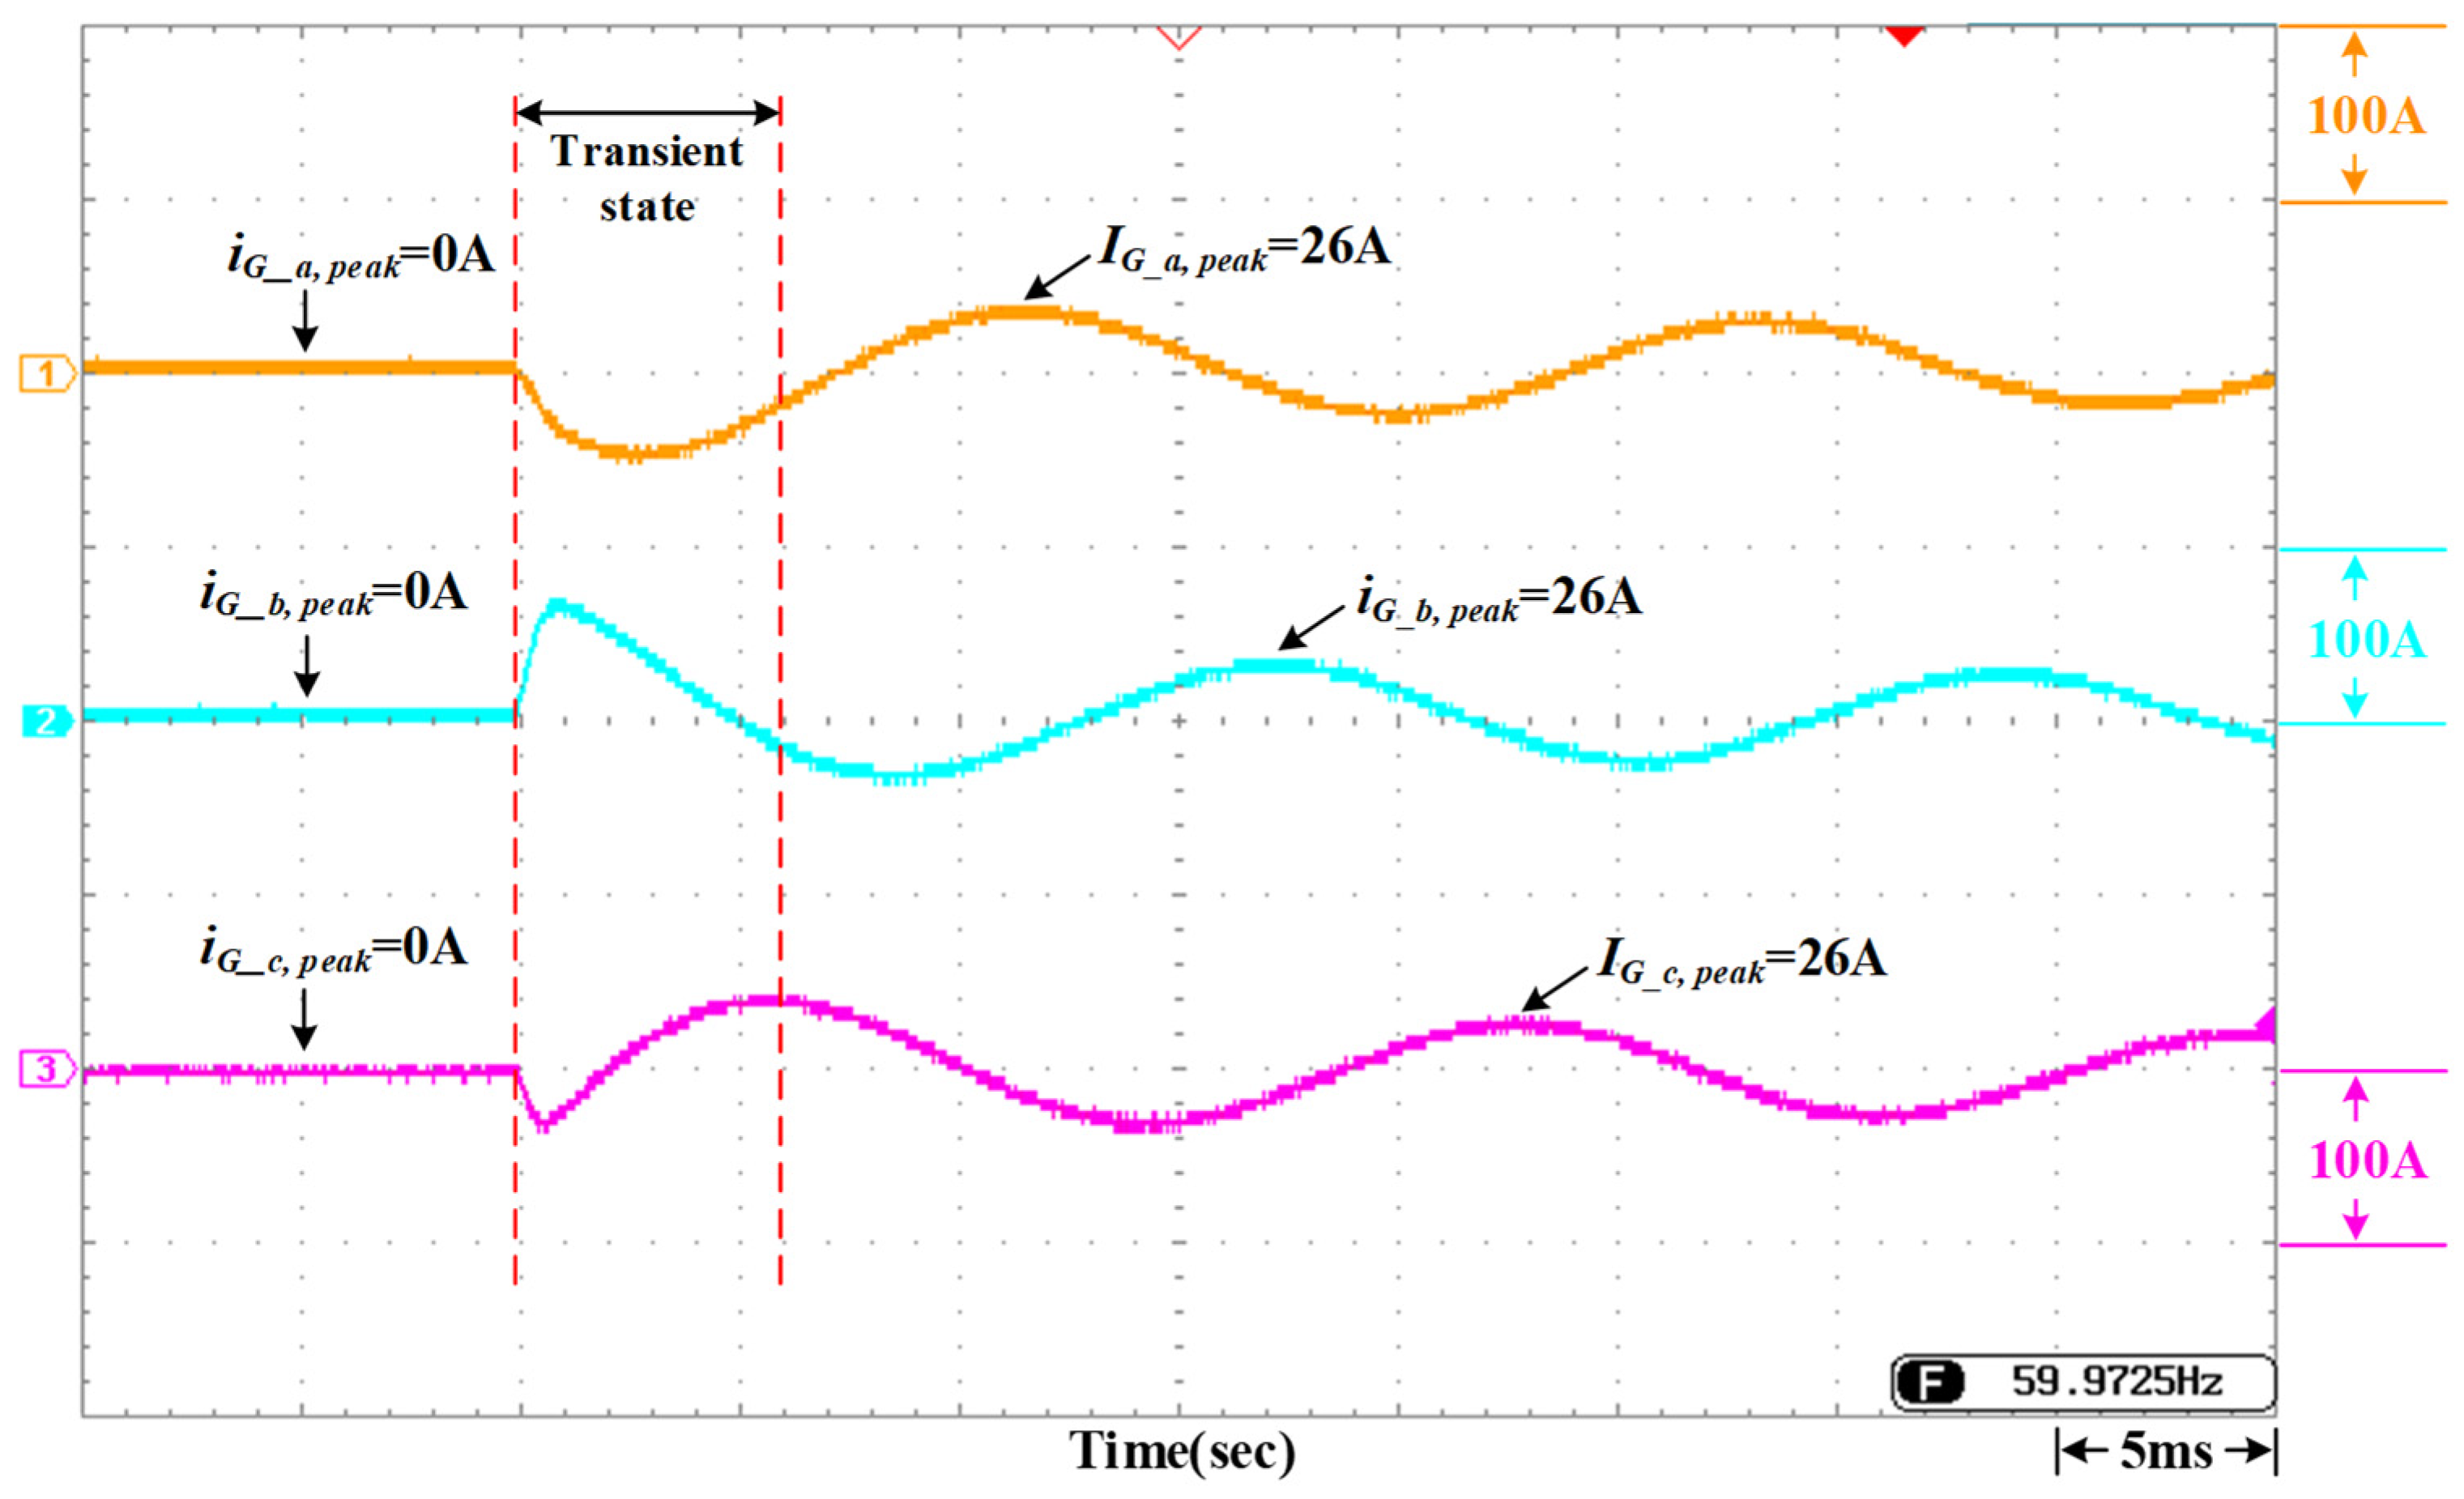
Furthermore, according to the measured output current waveforms of the grid in Figure 25, it can be observed that while the battery pack absorbs DC-link energy, the utility grid does not supply power to the load. Once the smart inverter outputs the entire energy from the PVMA, the AC-side load demand is supplied with priority, and the remaining surplus energy is absorbed by the grid.
Figure 25.
Measured three-phase output current waveforms on the grid side for Case 1 during peak periods.
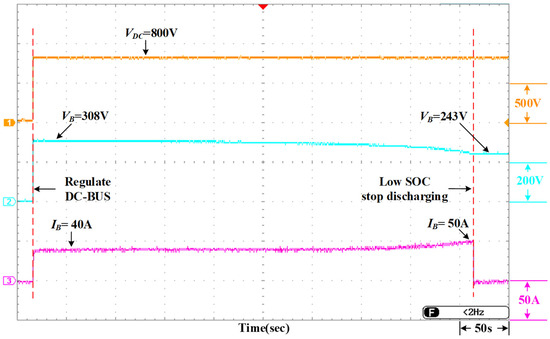
4.2.2. Case 2: Insufficient DC-Link Voltage with Battery SOC at 10%
This scenario occurs when the power generated by the PV module array is lower than the current demand of the smart inverter, leading to a decrease in the DC-link voltage. Upon detecting that the DC-link voltage is below the setpoint, the lithium-iron phosphate battery pack must compensate for the energy deficit in the DC link. However, once the battery’s SOC reaches 10%, it can no longer continue to regulate the DC-link voltage and must immediately cease discharging. The measured results for the DC-link voltage, battery terminal voltage, and current under this condition are shown in Figure 26.
Figure 26.
Measured results of DC-link voltage, battery terminal voltage, and current for Case 2 during peak periods.
Under this condition, according to the measured output current waveforms of the smart inverter in Figure 27, the battery pack initially compensates for the DC-link energy to meet the system voltage requirements. After the battery pack stops discharging, the smart inverter only delivers the total energy from the PVMA to the AC-side load, resulting in a decrease in the inverter’s output current.
Figure 27.
Measured output current waveforms of the smart inverter for Case 2 during peak periods.
Furthermore, according to the measured current results on the grid side in Figure 28, the utility grid does not supply power to the load while the battery pack is compensating for the DC-link energy. Once the battery power is insufficient and the smart inverter switches its control mode, the demand of the AC-side load is prioritized, and the remaining power deficit is compensated for by the grid.
Figure 28.
Measured output current waveforms on the grid side for Case 2 during peak periods.
4.3. Experimental Results of the Inverter Control Transition Between Peak and Off-Peak Periods
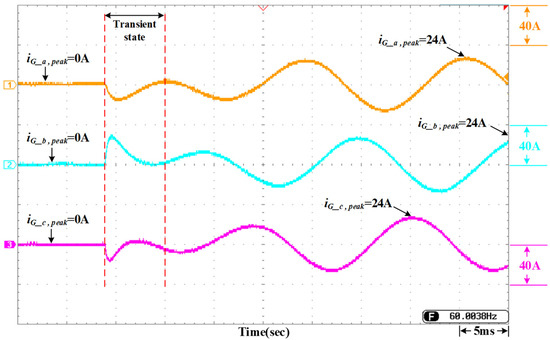
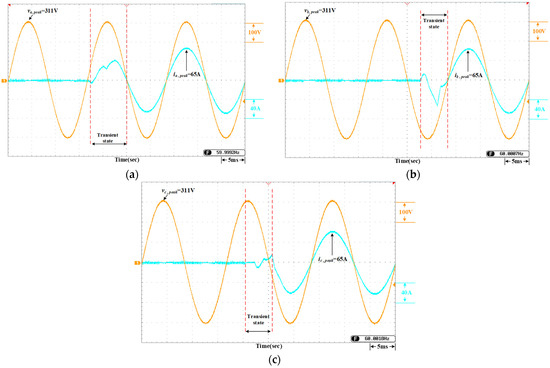
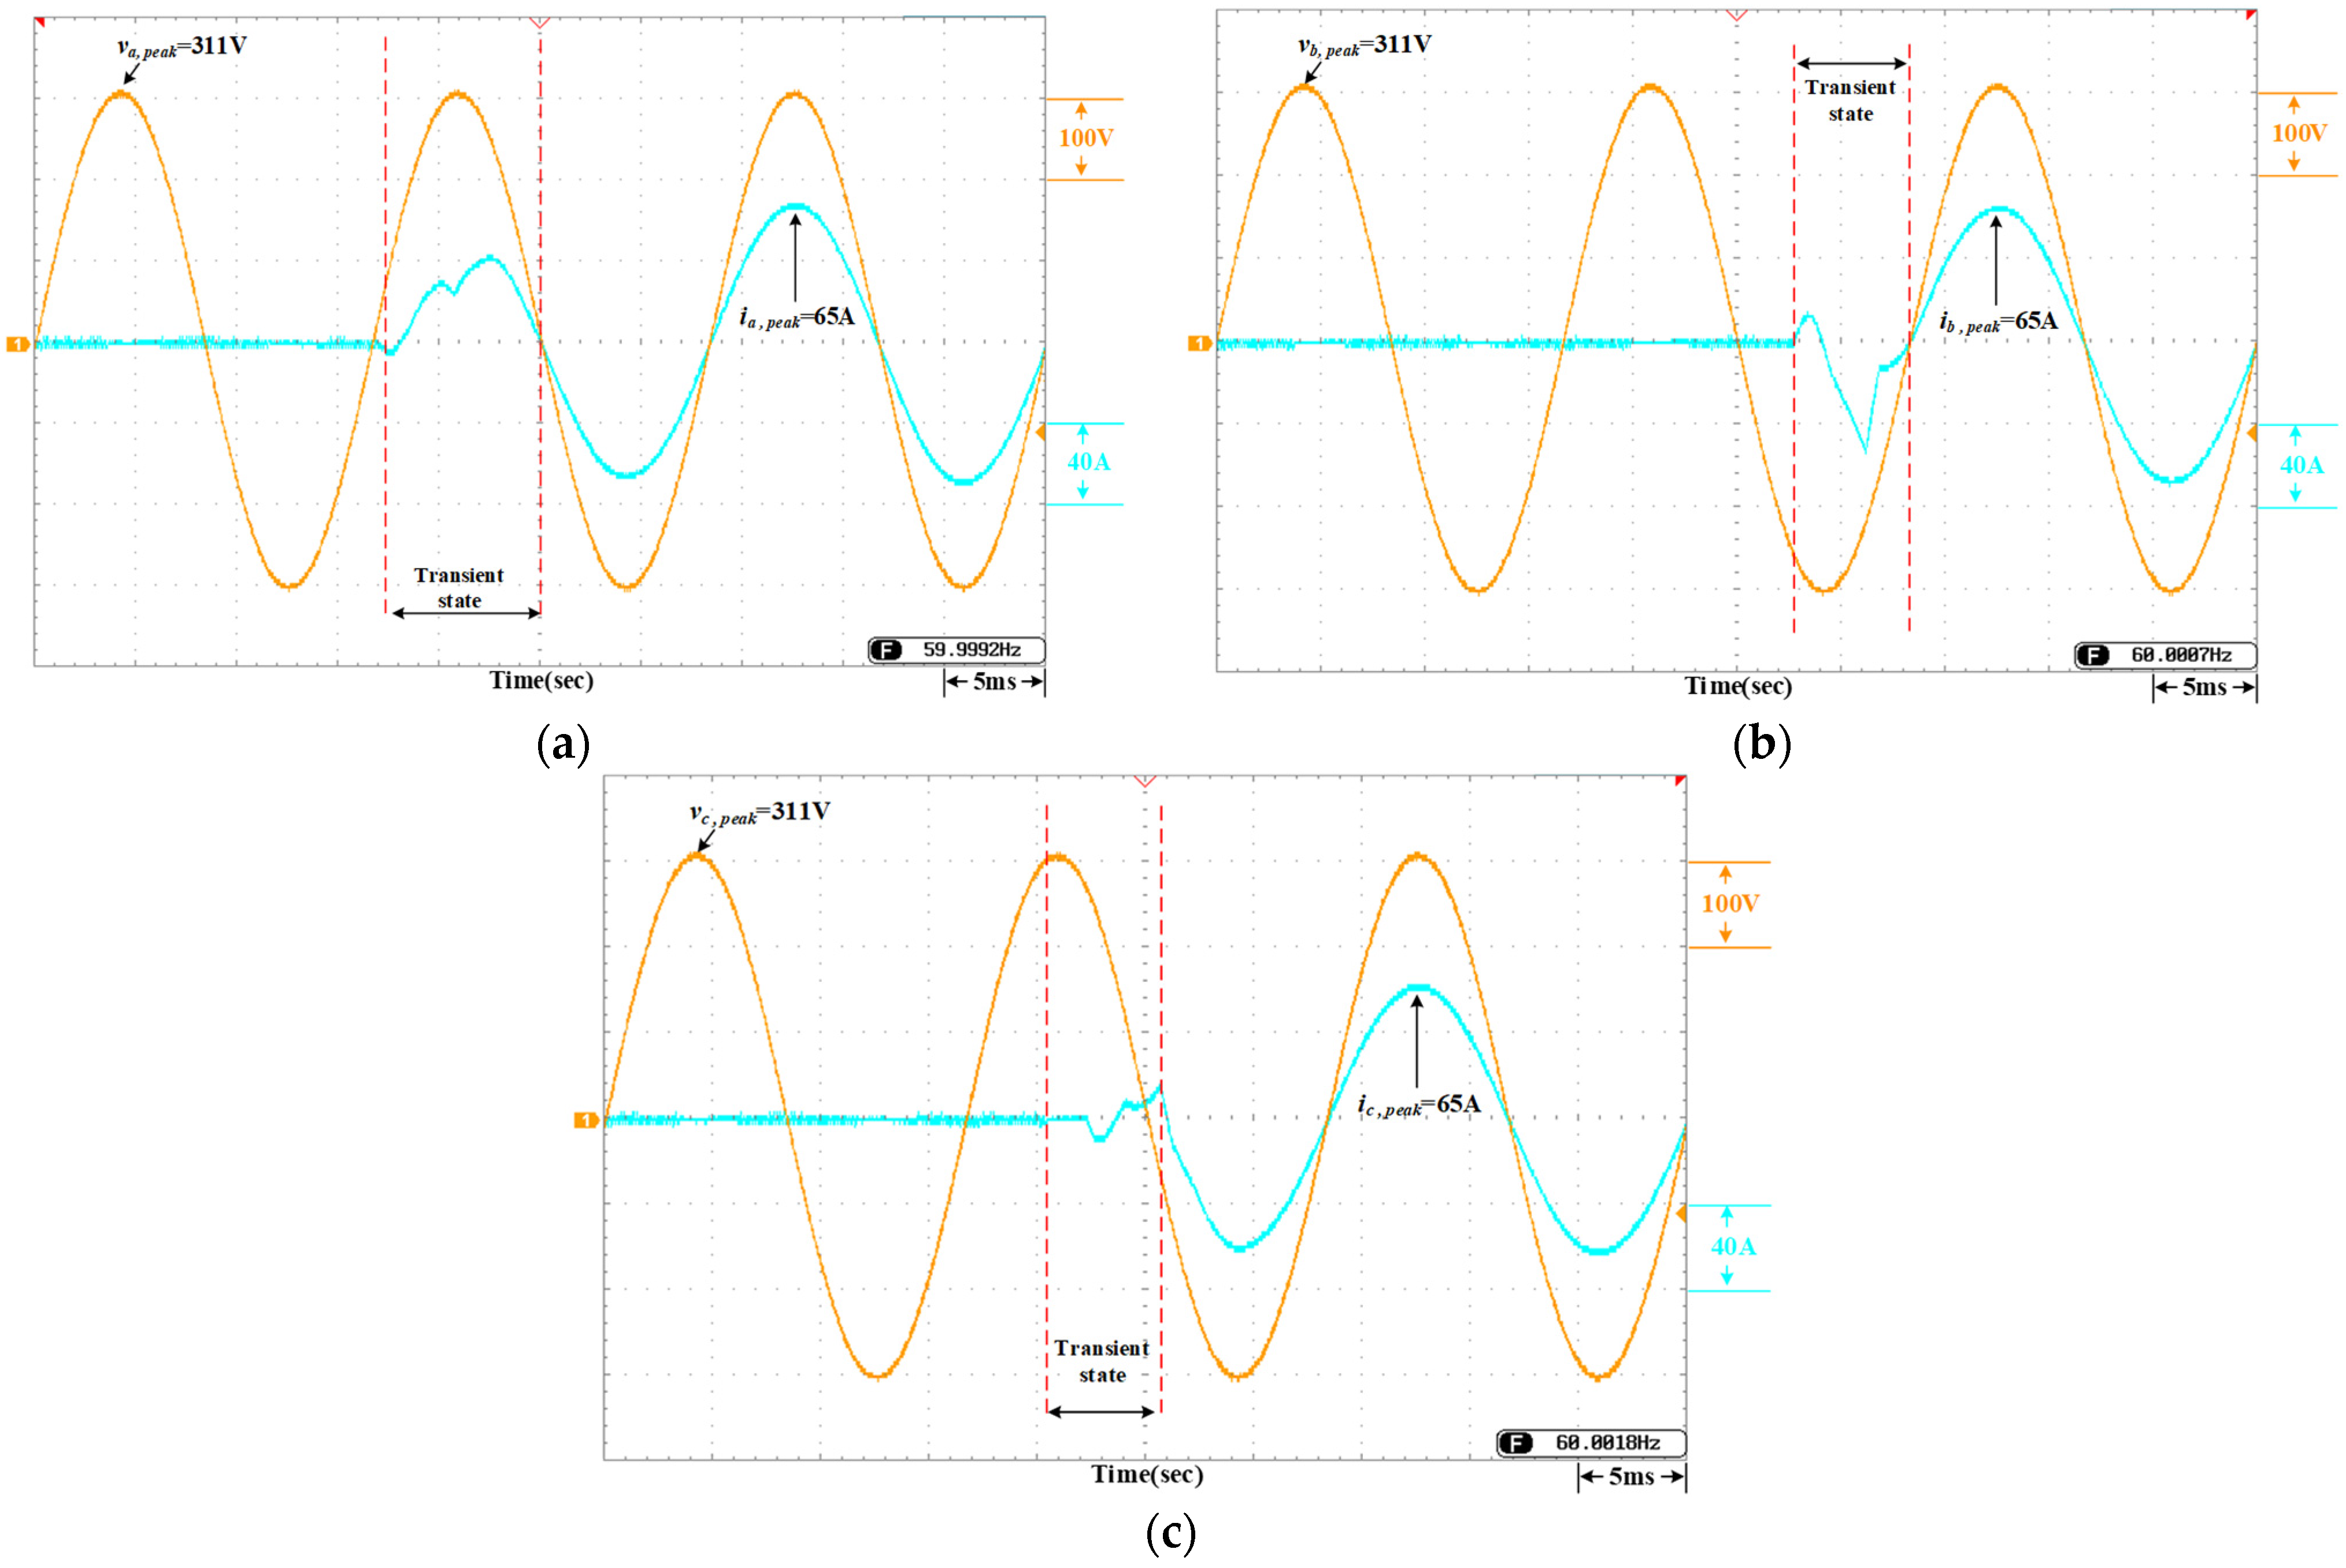
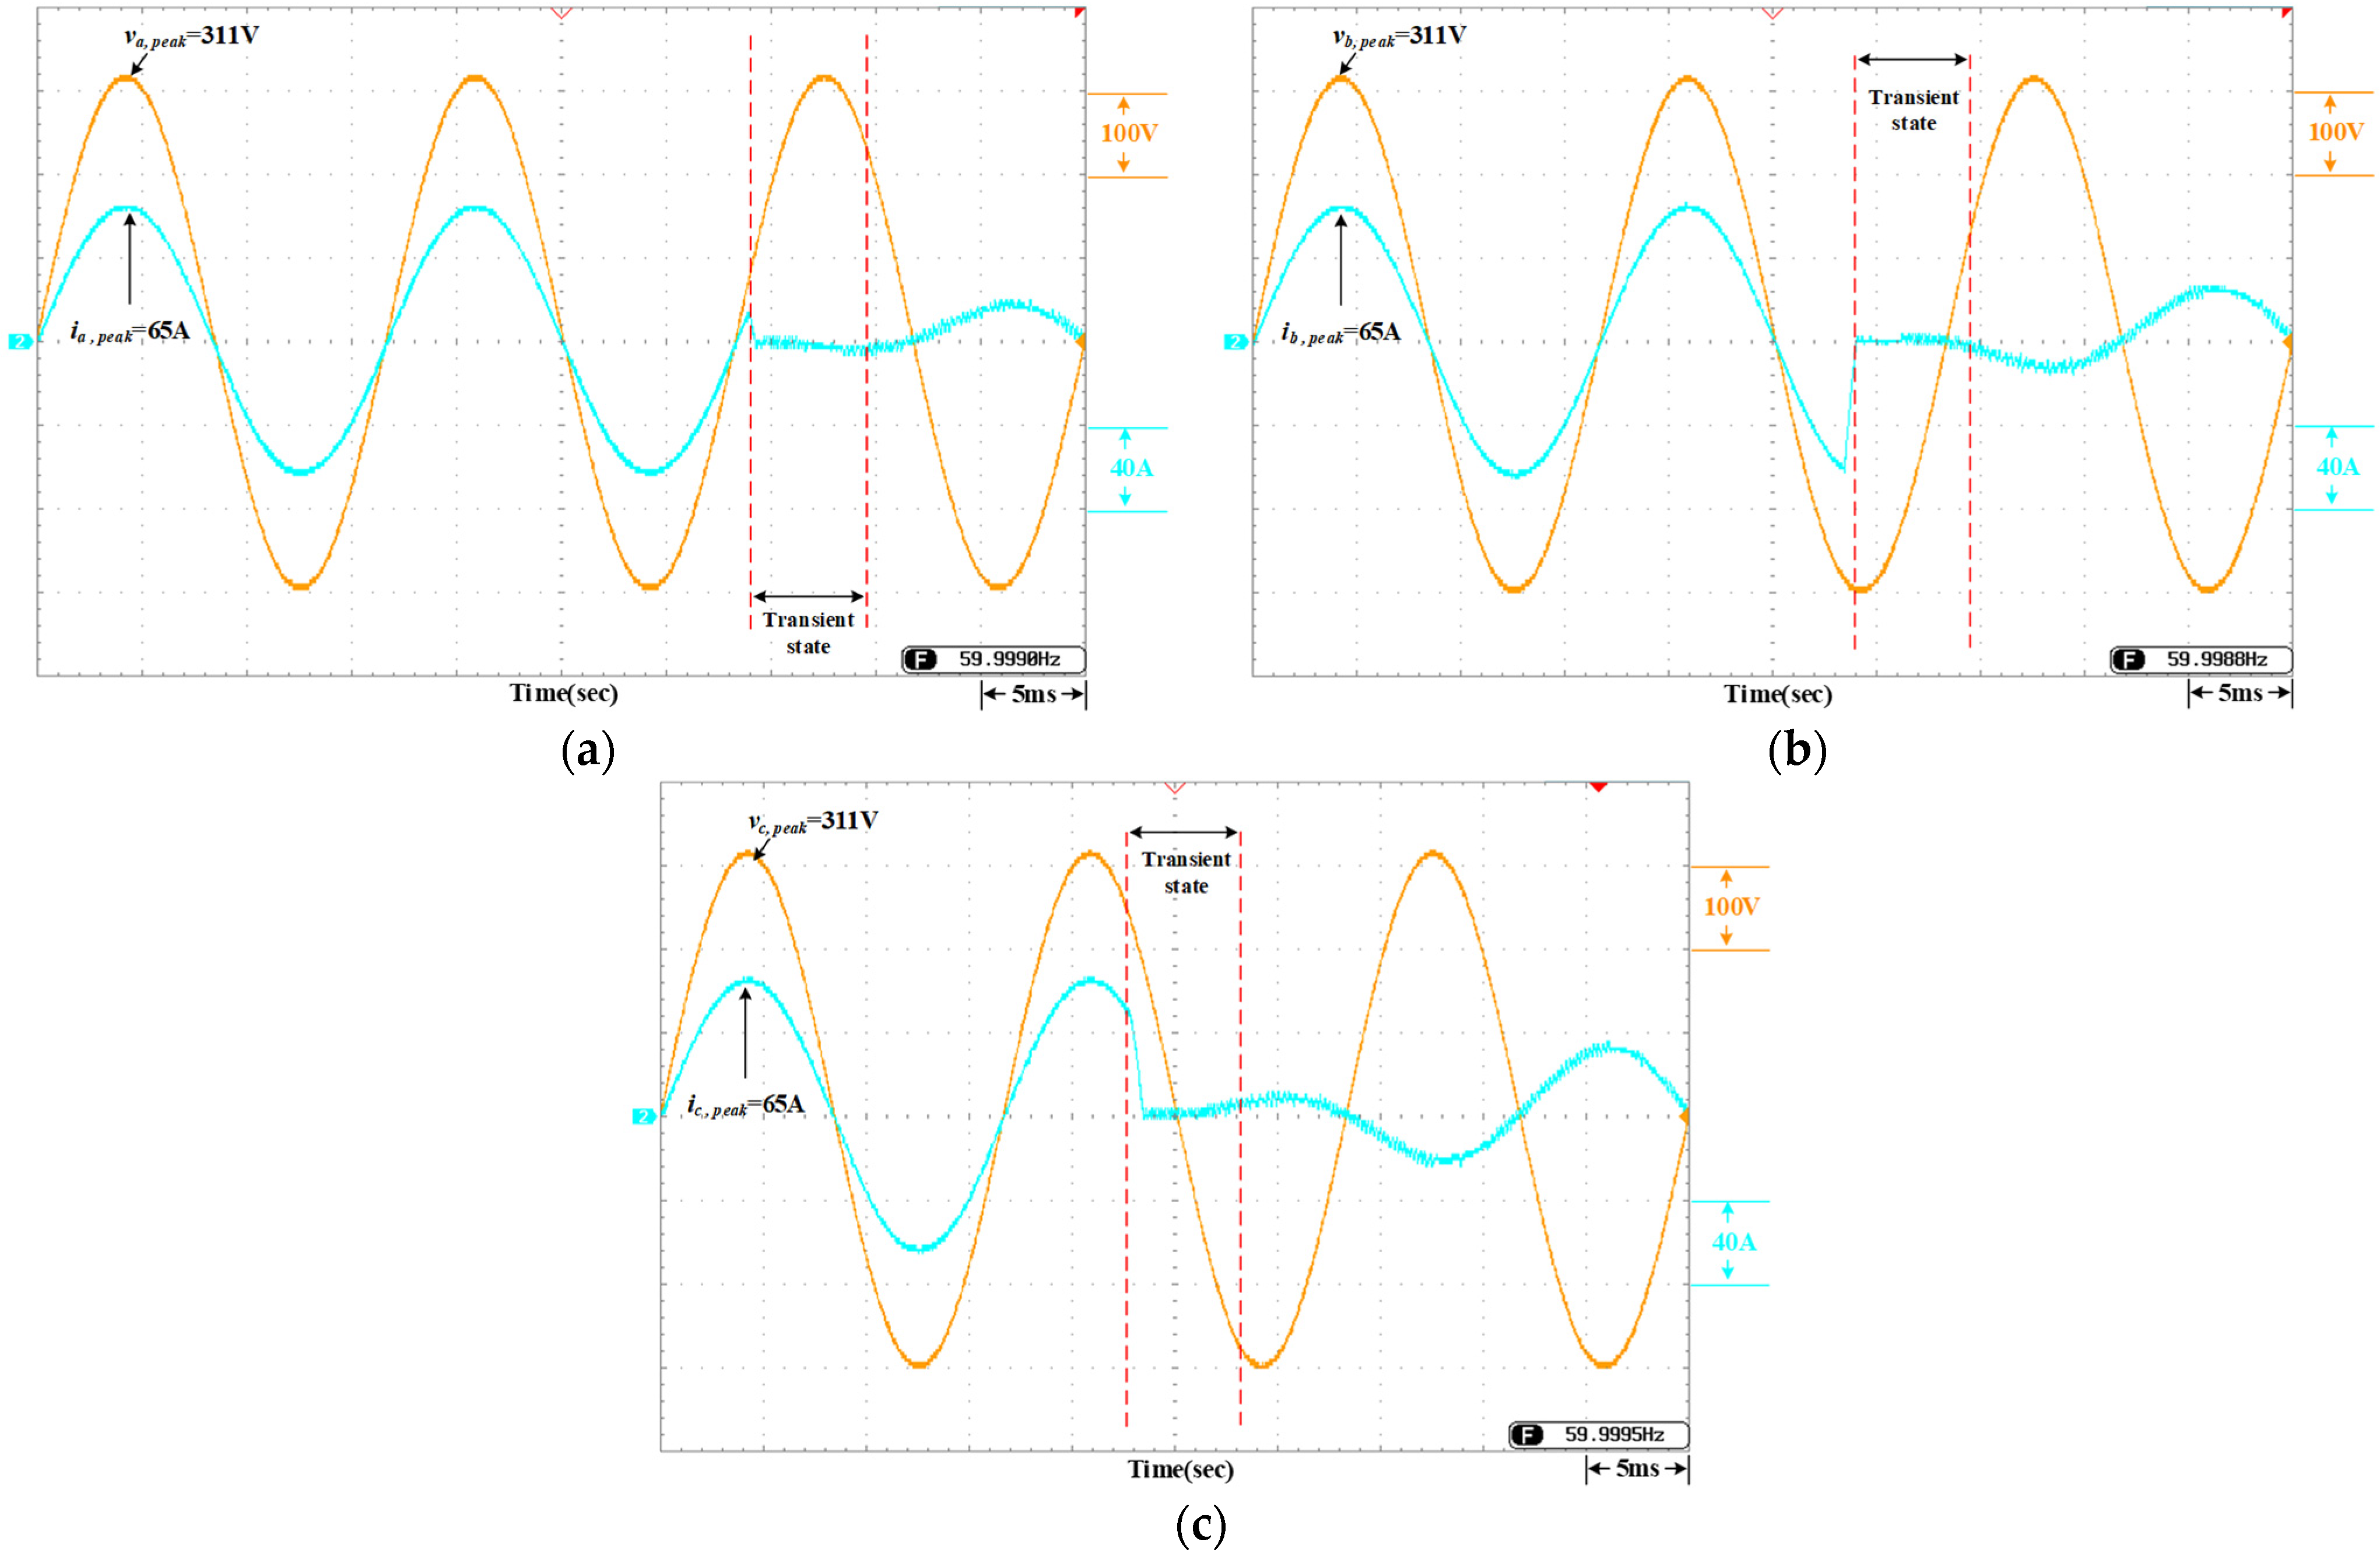
The energy dispatch strategy for peak shaving and valley filling based on the summer two-stage TOU electricity pricing discussed in this study applies off-peak rates from 00:00 AM to 9:00 AM, and peak rates after 9:00 AM. Therefore, the smart inverter determines whether to execute peak shaving or valley filling based on the time of day. The smart inverter performs controller mode transitions twice daily: from off-peak to peak mode, and from peak to off-peak mode. Thus, this section presents the experimental measurements of the inverter’s output voltage and current at the instant of control mode transition, which are described under two conditions.
4.3.1. Case 1: Transition from Off-Peak to Peak
After undergoing CC-CV charging during the off-peak period, the lithium-iron phosphate battery pack reaches a fully charged state and transitions to float mode; consequently, the charging current drawn from the grid side approaches zero. Under this operating state, the smart inverter switches to SPWM control. The measured results are illustrated in Figure 29. It can be observed from the figure that at the instant of the control mode transition, the three-phase currents of the smart inverter can recover to sinusoidal waveforms within a very short time. They remain in phase with the grid voltages, enabling the system to fully deliver active power to the utility grid, thereby improving the DC energy utilization efficiency of the PVMA and the battery pack.
Figure 29.
Measured output voltage and current waveforms of the inverter during the control transition from off-peak to peak: (a) phase a; (b) phase b; (c) phase c.
4.3.2. Case 2: Peak to Off-Peak Transition
Because the lithium-iron battery pack provides auxiliary power to the DC link during the peak period, its SOC is relatively low. Therefore, once the smart inverter switches to the hysteresis current control mode, it adopts a constant current for charging. Consequently, at the instant of control mode switching, the inverter’s output current instantaneously transitions from releasing electrical energy to absorbing it; the measured results are depicted in Figure 30. As observed in the figure, the three-phase currents are in phase with the grid voltage during the peak period. Upon entering the off-peak period, the inverter draws energy from the grid to charge the battery, causing the currents to be in anti-phase with the grid voltage. At the exact moment of the control mode transition, the three-phase currents can track the grid phase within an extremely short time, thereby enhancing the power supply stability and power quality of the grid-side power equipment.
Figure 30.
Measured waveforms of the inverter output voltage and current during the control transition from peak to off-peak periods: (a) phase a; (b) phase b; (c) phase c.
To provide a clear quantitative evaluation, representative transient duration, steady-state error, and ripple values of the DC link voltage VDC are summarized in Table 7 to complement the experimental waveform plots presented in Figure 19, Figure 21, Figure 23 and Figure 25. In addition, Table 8 presents a comprehensive comparison of key performance indicators between the business-as-usual scenario and the proposed method, demonstrating the quantitative improvements achieved by the proposed control strategy.
Table 7.
Quantitative performance metrics under various operating scenarios.
Table 8.
Comparison of key performance indicators between the baseline scenario without control and the proposed method.
5. Conclusions
Both the simulation and the experimental results confirm that during the bidirectional power conversion process of the smart inverter, the power factor between the output voltage and current exceeds 0.99 in both off-peak and peak periods, with the grid current THD strictly maintained below 5%. Furthermore, when controlled by the inverter, the three-phase currents can rapidly track the real-time phase of the grid, thereby enhancing the overall energy efficiency of the power system. Regarding the peak-shaving and valley-filling control, to verify that the proposed controller enables a fast energy-regulation response for the lithium-iron battery pack, the stability of the CC-CV charging controller and the over-contract prevention charging controller were experimentally evaluated during off-peak periods. It was also verified that the lithium-iron battery pack is capable of instantly detecting grid over-contract conditions and adjusting the charging current accordingly. Moreover, during peak periods, by regulating the DC-link voltage, the lithium-iron battery pack can quickly determine whether the power generation from the PVMA exceeds the demand. From an operational performance perspective, taking the 35 kW contract capacity considered in this study as an example, the proposed peak-shaving strategy can effectively prevent up to 66.4 kWh of over-contract energy consumption per day. Furthermore, the DC-link voltage transient settling time ranges from 20 to 40 ms across various operating scenarios, with a voltage ripple below 2% and a boost converter efficiency of 89.5%. When combined with a time-of-use (TOU) operation scheme, the proposed control strategy enables effective energy scheduling between off-peak and peak periods while maintaining the grid power demand within the prescribed contract capacity limits. However, a comprehensive techno-economic assessment, including cost-saving benefits, payback-period analysis, and other related economic indicators, is beyond the scope of this study and is therefore not addressed herein. It is worth noting that the proposed peak-shaving and valley-filling control strategy is designed to operate independently of consumer behavior, making it effective even under inflexible load conditions. The anti-over-contract-capacity protection mechanism continuously monitors real-time grid power and dynamically regulates the battery charging current to ensure compliance with the contractual capacity limit. Therefore, the proposed strategy remains capable of preventing over-contract penalties regardless of whether the connected loads are flexible or inflexible. Nevertheless, the integration of flexible loads through demand response participation can further reduce the battery discharge burden during peak periods, thereby alleviating battery stress and potentially extending battery lifetime. The actual effectiveness of the strategy may vary depending on consumer characteristics, load profiles, and demand response participation levels. Future work will incorporate detailed consumer-profile modeling and flexible-load scenarios to provide a more comprehensive assessment of system performance under different application conditions. In addition, future interdisciplinary research will explore the integration of advanced energy storage materials, including MXenes and other emerging two-dimensional (2D) materials, to further enhance battery performance, energy storage capability, and system reliability. Advanced battery characterization techniques, such as in situ and operando diagnostics, may also be employed to provide deeper insights into battery behavior and long-term operational stability, thereby supporting the development of next-generation energy storage systems.
Author Contributions
Conceptualization, project administration, writing—review and editing and resources: K.-H.C.; Software and writing—original draft: Y.-H.W.; Methodology and formal analysis: C.-D.W. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflict of interest.
Nomenclature
| Acronyms | |
| PV | Photovoltaic |
| TOU | Time-of-use |
| MPPT | Maximum power point tracking |
| SPWM | Sinusoidal pulse-width modulation |
| BESS | Battery energy storage systems |
| PFC | Power factor correction |
| THD | Total harmonic distortion |
| MPC | Model predictive control |
| SOC | State of charge |
| V2G | Vehicle-to-grid |
| ESS | Energy storage systems |
| CC-CV | Constant current–constant voltage |
| SRF-PLL | Synchronous reference frame phase-locked loop |
| P-I | Proportional-integral |
| q-axis | Quadrature axis |
| d-axis | Direct axis |
| PLL | Phase-locked loop |
| CV | Constant voltage |
| DOD | Depth of discharge |
| CC | Constant current |
| Symbols | |
| Current control command (A) | |
| Maximum charging current reference (A) | |
| Battery current (A) | |
| P-I gains of the current loop controller | |
| Battery current command (A) | |
| Maximum battery voltage (V) | |
| Battery voltage (V) | |
| P-I gains of the voltage loop controller | |
| Contract capacity power (W) | |
| Actual grid power (W) | |
| P-I gains of the power loop controller | |
| d-axis reference current (A) | |
| dc-link reference voltage (V) | |
| dc-link voltage (V) | |
| P-I gains of dc-link voltage controller | |
| Reference power (W) | |
| Peak reference current (A) | |
| Peak grid voltage (V) | |
| Peak shaving power (W) | |
| Load demand power (W) | |
| Contract capacity power (V) | |
| Voltage component of the d-axis and q-axis (V) | |
| P-I gains of d-axis current controller | |
| Current of the d-axis and q-axis (A) | |
| P-I gains of voltage outer loop controller | |
| P-I gains of current inner loop controller | |
| P-I gains of dc-link voltage controller |
References
- Watari, D.; Taniguchi, I.; Onoye, T. Duck Curve Aware Dynamic Pricing and Battery Scheduling Strategy Using Reinforcement Learning. IEEE Trans. Smart Grid 2023, 15, 457–471. [Google Scholar] [CrossRef] [Scilit]
- Smith, J.; Wang, L. Duck Curve Mitigation and Peak-Shaving Strategies via Enhanced Battery Scheduling and TOU Pricing. Sustain. Energy Grids Netw. 2025, 41, 102051. [Google Scholar]
- Remache, S.; Remache, S.E.I.; Barra, K. Algeria Power Management of Grid Connected PV System with Integrated Energy Storage. In Proceedings of the 1st International Conference on Sustainable Renewable Energy Systems and Applications (ICSRESA), Tebessa, Algeria, 4–5 December 2019; pp. 1–4. [Google Scholar]
- Attou, N.; Zidi, S.-A.; Hadjeri, S.; Khatir, M. Improved Peak Shaving and Valley Filling Using V2G Technology in Grid Connected Microgrid. In Proceedings of the 3rd International Conference on Transportation and Smart Technologies (TST), Oran, Algeria, 27–28 May 2021; pp. 53–58. [Google Scholar]
- Kumar, D.; Das, M. Optimized Charging Method for Fast Charging of EV Batteries. In Proceedings of the 49th Annual Conference of the IEEE Industrial Electronics Society (IECON), Singapore, 16–19 October 2023; pp. 1–6. [Google Scholar]
- Pavlova, Y.V.; Grigorii, B.V. The Synthesis of a Control System of the Active Rectifier. In Proceedings of the IEEE Conference of Russian Young Researchers in Electrical and Electronic Engineering (EIConRus), Moscow/St. Petersburg, Russia, 29 January–1 February 2018; pp. 941–944. [Google Scholar]
- Saaravia-Guerrero, J.A.; EsP-Inosa-Juárez, E. Optimal Sizing of BESS for Industrial Peak Shaving Applications Considering Different Electricity Billing Rates. In Proceedings of the 4th International Conference on Electrical, Computer and Communication Technologies (ICECCT), Erode, India, 15–17 September 2021; pp. 1–6. [Google Scholar]
- Manandhar, U.; Ukil, A.; Beng Gooi, H.; Tummuru, N.R.; Kollimalla, S.K. A Low Complexity Control and Energy Management for DC-coupled Hybrid Microgrid with Hybrid Energy Storage System. In Proceedings of the IEEE Power & Energy Society General Meeting, Chicago, IL, USA, 16–20 July 2017; pp. 1–5. [Google Scholar]
- Rao, C.V.R.; Ganesh, M.S.R.; Sekhar, K.C.; Sudha, R.P.; Dangeti, L.K.; Duvvuri, S.S.S.R.S. A Generalized MPPT Controlled DC-DC Boost Converter for PV System Connected to Utility Grid. In Proceedings of the Innovations in Power and Advanced Computing Technologies, Vellore, India, 22–23 March 2019; pp. 1–5. [Google Scholar]
- Jian, J.J. Energy Storage System with Uniform Battery Charging and Discharging Control. Master’s Thesis, National Chin-Yi University of Technology, Taichung, Taiwan, 2020. [Google Scholar]
- Cha, H.; Vu, T.K. Comparative Analysis of Low-pass Output Filter for Single-phase Grid-connected Photovoltaic Inverter. In Proceedings of the 25th Annual IEEE Applied Power Electronics Conference and Exposition (APEC), Palm Springs, CA, USA, 21–25 February 2010; pp. 1659–1665. [Google Scholar]
- Channegowda, P.; John, V. Filter Optimization for Grid Interactive Voltage Source Inverters. IEEE Trans. Ind. Electron. 2010, 57, 4106–4114. [Google Scholar] [CrossRef] [Scilit]
- Boumassata, A.; Chourouk, B.; Achouak, S. Experimental Validation of P&O and P&O-P-I MPPT Using RT-Lab under Real Atmospheric Conditions. In Proceedings of the 2nd International Conference on Electronics, Energy and Measurement (IC2EM), Boumerdes, Algeria, 28–30 November 2023; pp. 1–6. [Google Scholar]
- Ba, O.A.; Ndiaye, A.; Ba, A.; Ndiaye, E.H.M.; Tankari, M.A. Optimization of the P&O-MPPT Controller by the Adaptive Method (Ad-P&O) for Stand-alone PV Systems. In Proceedings of the 11th International Conference on Smart Grid (icSmartGrid), Paris, France, 4–7 June 2023; pp. 1–8. [Google Scholar]
- Sonam, K.; Nikhil, P.; Sudeep, B.; Atul, G. Implementation of Single-phase Modified SRF-PLL Using Model Based Development Approach. In Proceedings of the North American Power Symposium (NAPS), Morgantown, WV, USA, 17–19 September 2017; pp. 1–6. [Google Scholar]
- Zhou, G.; Shi, X.; Fu, C.; Wang, Y. Operation of a Three-phase Soft Phase Locked Loop under Distorted Voltage Conditions Using Intelligent P-I Controller. In Proceedings of the IEEE Region 10 Technical Conference (TENCON), Hong Kong, China, 14–17 November 2006; pp. 1–4. [Google Scholar]
- Zou, Y.; Zhang, L.; Xing, Y.; Zhang, Z.; Zhao, H.; Ge, H. Generalized Clarke Transformation and Enhanced Dual-loop Control Scheme for Three-phase PWM Converters under the Unbalanced Utility Grid. IEEE Trans. Power Electron. 2022, 37, 8935–8947. [Google Scholar]
- Triki, Y.; Bechouche, A.; Seddiki, H.; Abdeslam, D.O. Improved D-Q Frame Controller for Stand-alone Single-phase Inverters. In Proceedings of the IEEE International Conference on Industrial Technology (ICIT), Buenos Aires, Argentina, 26–28 February 2020; pp. 53–58. [Google Scholar]
- Mennai, N.; Soufi, Y.; Medoued, A.; Faleh, A. Grid Synchronization Techniques Analysis of DG Systems under Grid Fault Conditions. In Proceedings of the 19th International Multi-Conference on Systems, Signals & Devices (SSD), Setif, Algeria, 6–10 May 2022; pp. 917–922. [Google Scholar]
- Chaudhary, C.; Mishra, S.; Nangia, U. A Bridgeless Isolated Zeta Converter for Battery Charging Aided with Solar Photovoltaic System. In Proceedings of the International Conference on Smart Generation Computing, Communication and Networking (SMART GENCON), Pune, India, 29–30 October 2021; pp. 1–6. [Google Scholar]
- Bouhouta, A.; Moulahoum, S.; Kabache, N.; Benyamina, A. Design and Real Time Implementation of Three Phase Shunt Active Power Filter Using Indirect Current Control Technique. In Proceedings of the International Conference on Advanced Electrical Engineering (ICAEE), El Oued, Algeria, 19–21 November 2019; pp. 1–6. [Google Scholar]
- Zhang, C.; Yu, S.; Jiang, K.; Ge, X.; Ma, J. A Fast Instantaneous Power Calculation Algorithm for Single-phase Rectifiers Based on Arbitrary Phase-delay Method. IEEE Trans. Ind. Appl. 2019, 55, 3935–3945. [Google Scholar]
- Dong, H.; Jun, S.; Qiang, Z.; Liang, Z.; Chuanxiu, W. Control Strategy of Grid Connected Photovoltaic Power with Energy Storage System. In Proceedings of the IEEE 4th Information Technology, Networking, Electronic and Automation Control Conference (ITNEC), Chongqing, China, 12–14 June 2020; pp. 2409–2413. [Google Scholar]
- Data Sheet of A10 Green Technology A10J-M60-225 Solar Panel. Available online: http://www.solarhub.com/solarhub_products/3317-A10J-M60-225-A10Green-Technology (accessed on 25 December 2024).
- Data Sheet of A123 Li-Iron-Phosphate ANR26650M1. Available online: https://www.sullivanuv.com/wp-content/uploads/2014/06/A123-Cell-Datasheet-2008-08.pdf (accessed on 25 December 2024).
- Plexim GmbH. PLECS User Manual; Plexim GmbH: Zurich, Switzerland, 2022; Available online: https://www.plexim.com/sites/default/files/plecsmanual.pdf (accessed on 25 December 2024).
- Liu, J.; Gao, D.; Cao, J. Study on the Effects of Temperature on LiFePO4 Battery Life. In Proceedings of the IEEE Vehicle Power and Propulsion Conference, Seoul, Republic of Korea, 9–12 October 2012; pp. 1436–1440. [Google Scholar]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.