
Designing Extended Intelligence: A Taxonomy of Psychobiological Effects of XR–AI Systems for Human Capability Augmentation
 , , ,
Abstract
1. Introduction
2. Method and Materials
2.1. Study Design
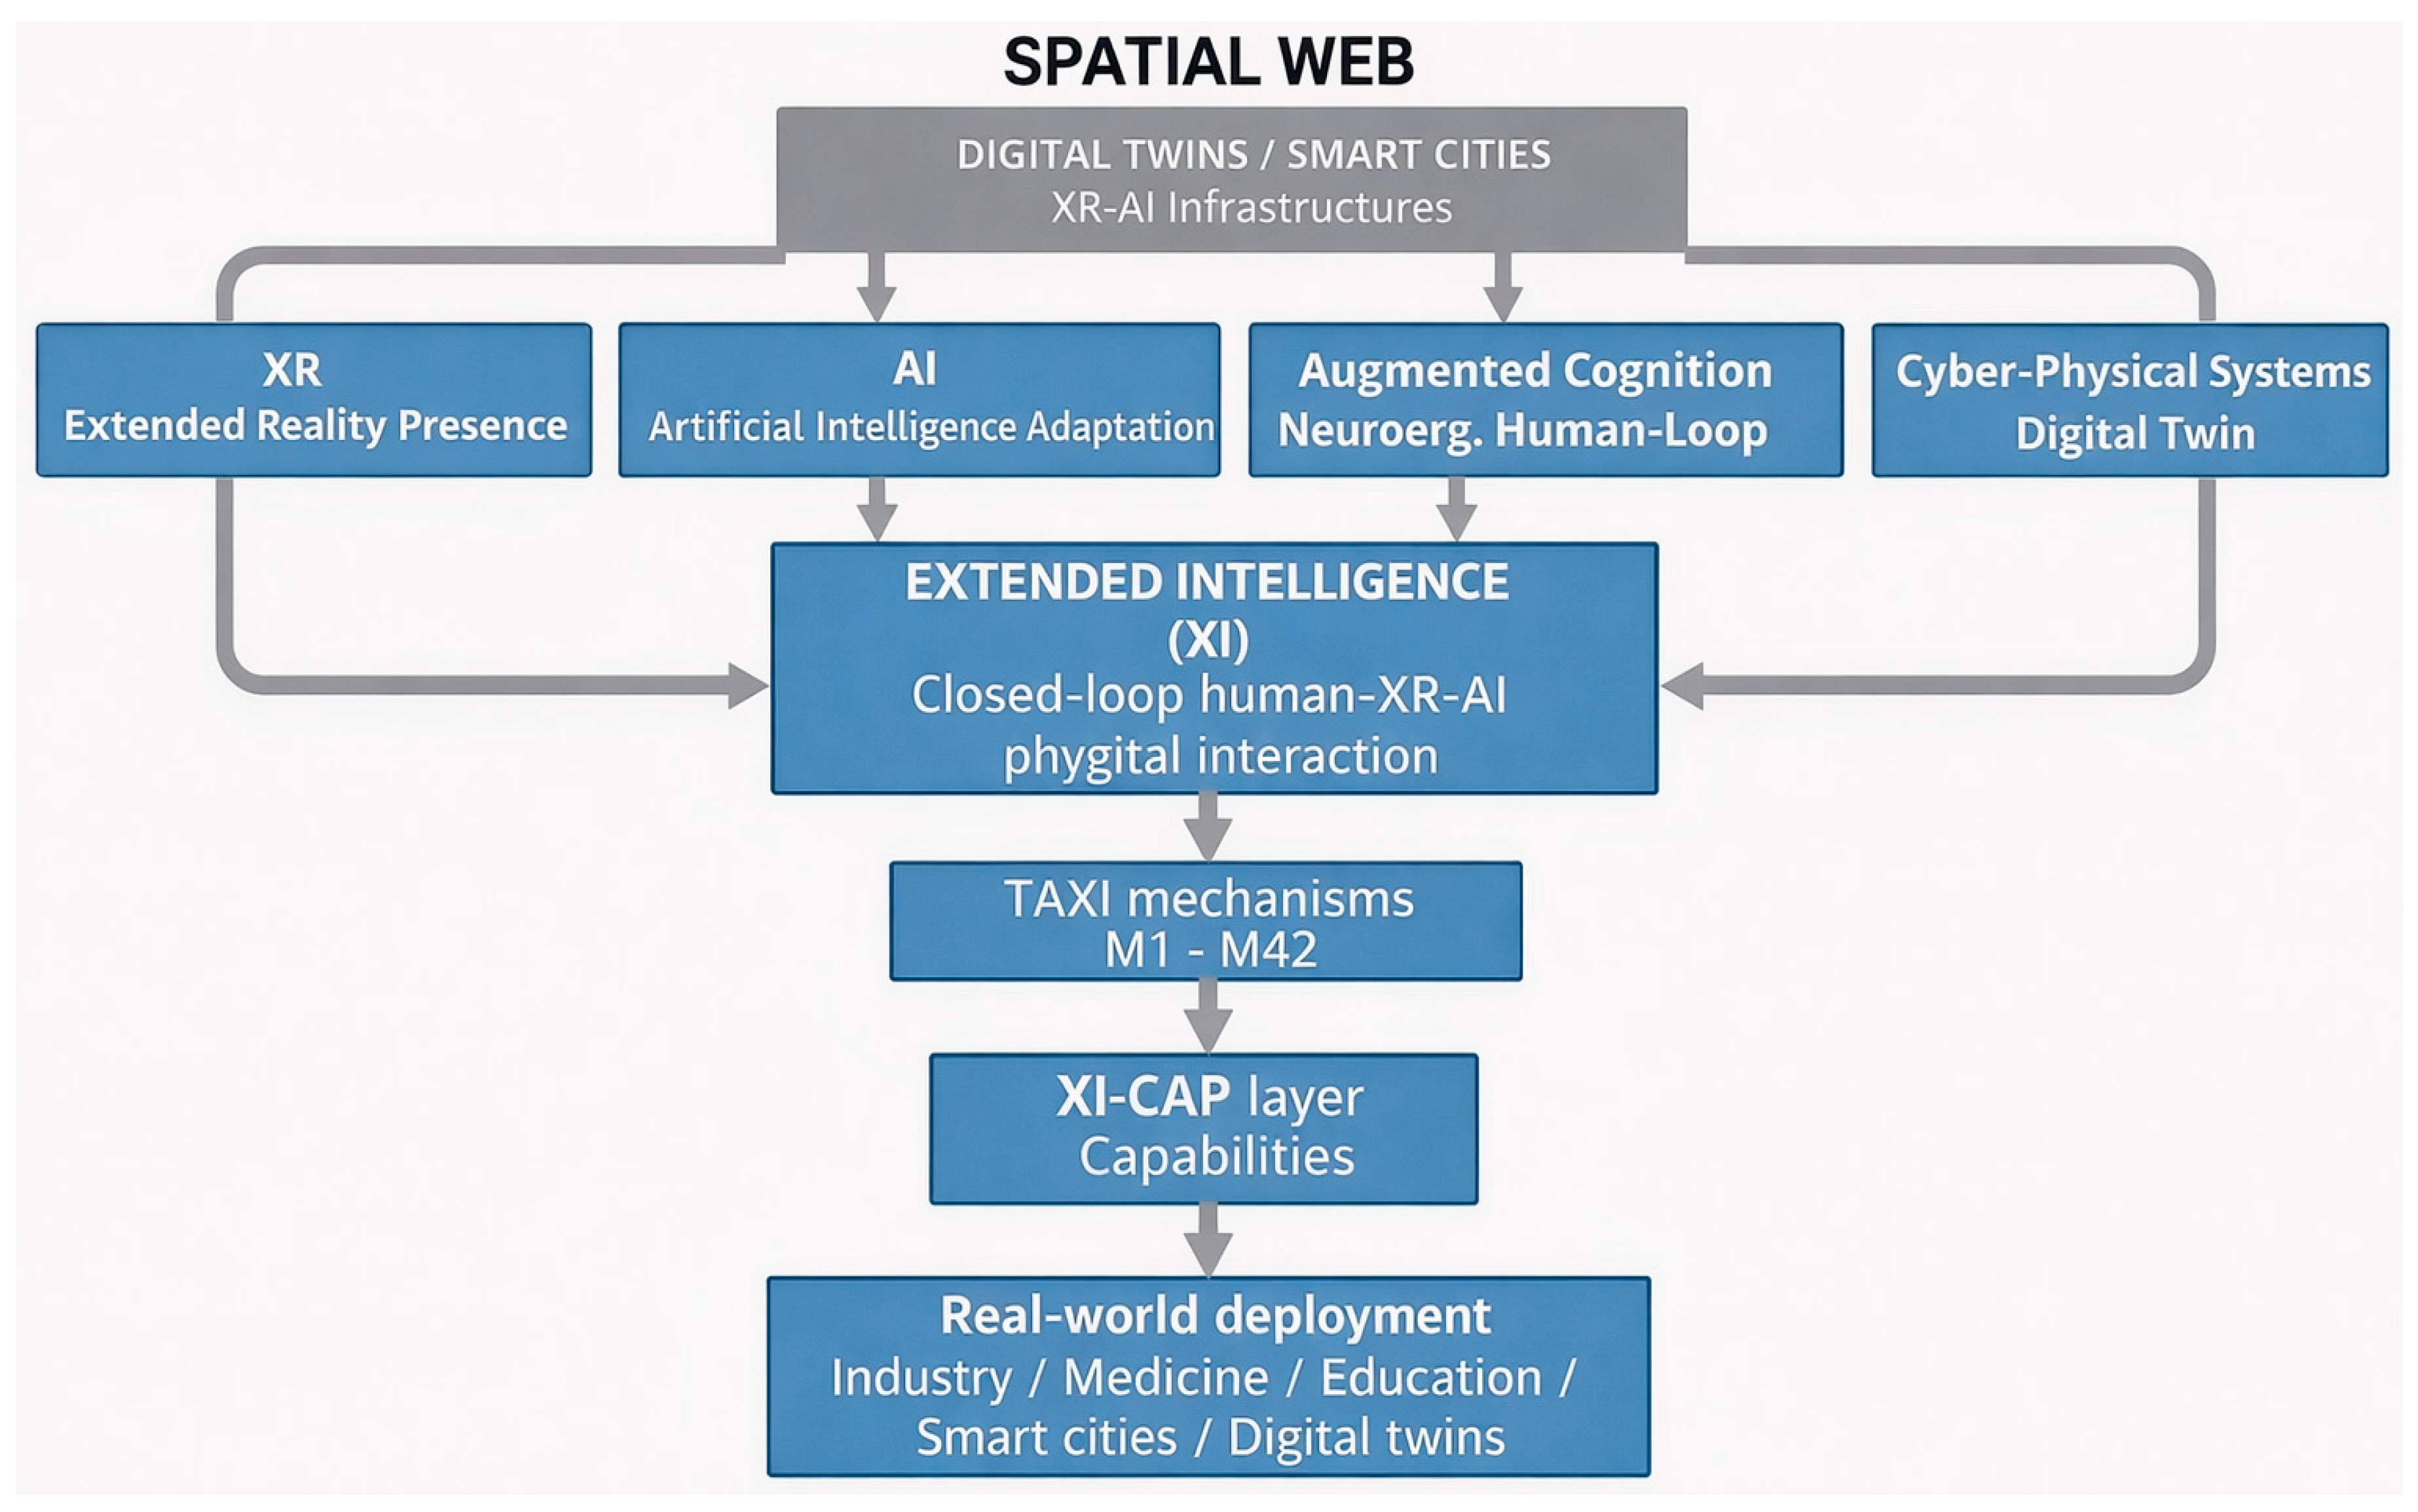
- construction of a psychobiological mechanism taxonomy (TAXI) layer;
- derivation of the connection to an augmented capability (XI-CAP) layer;
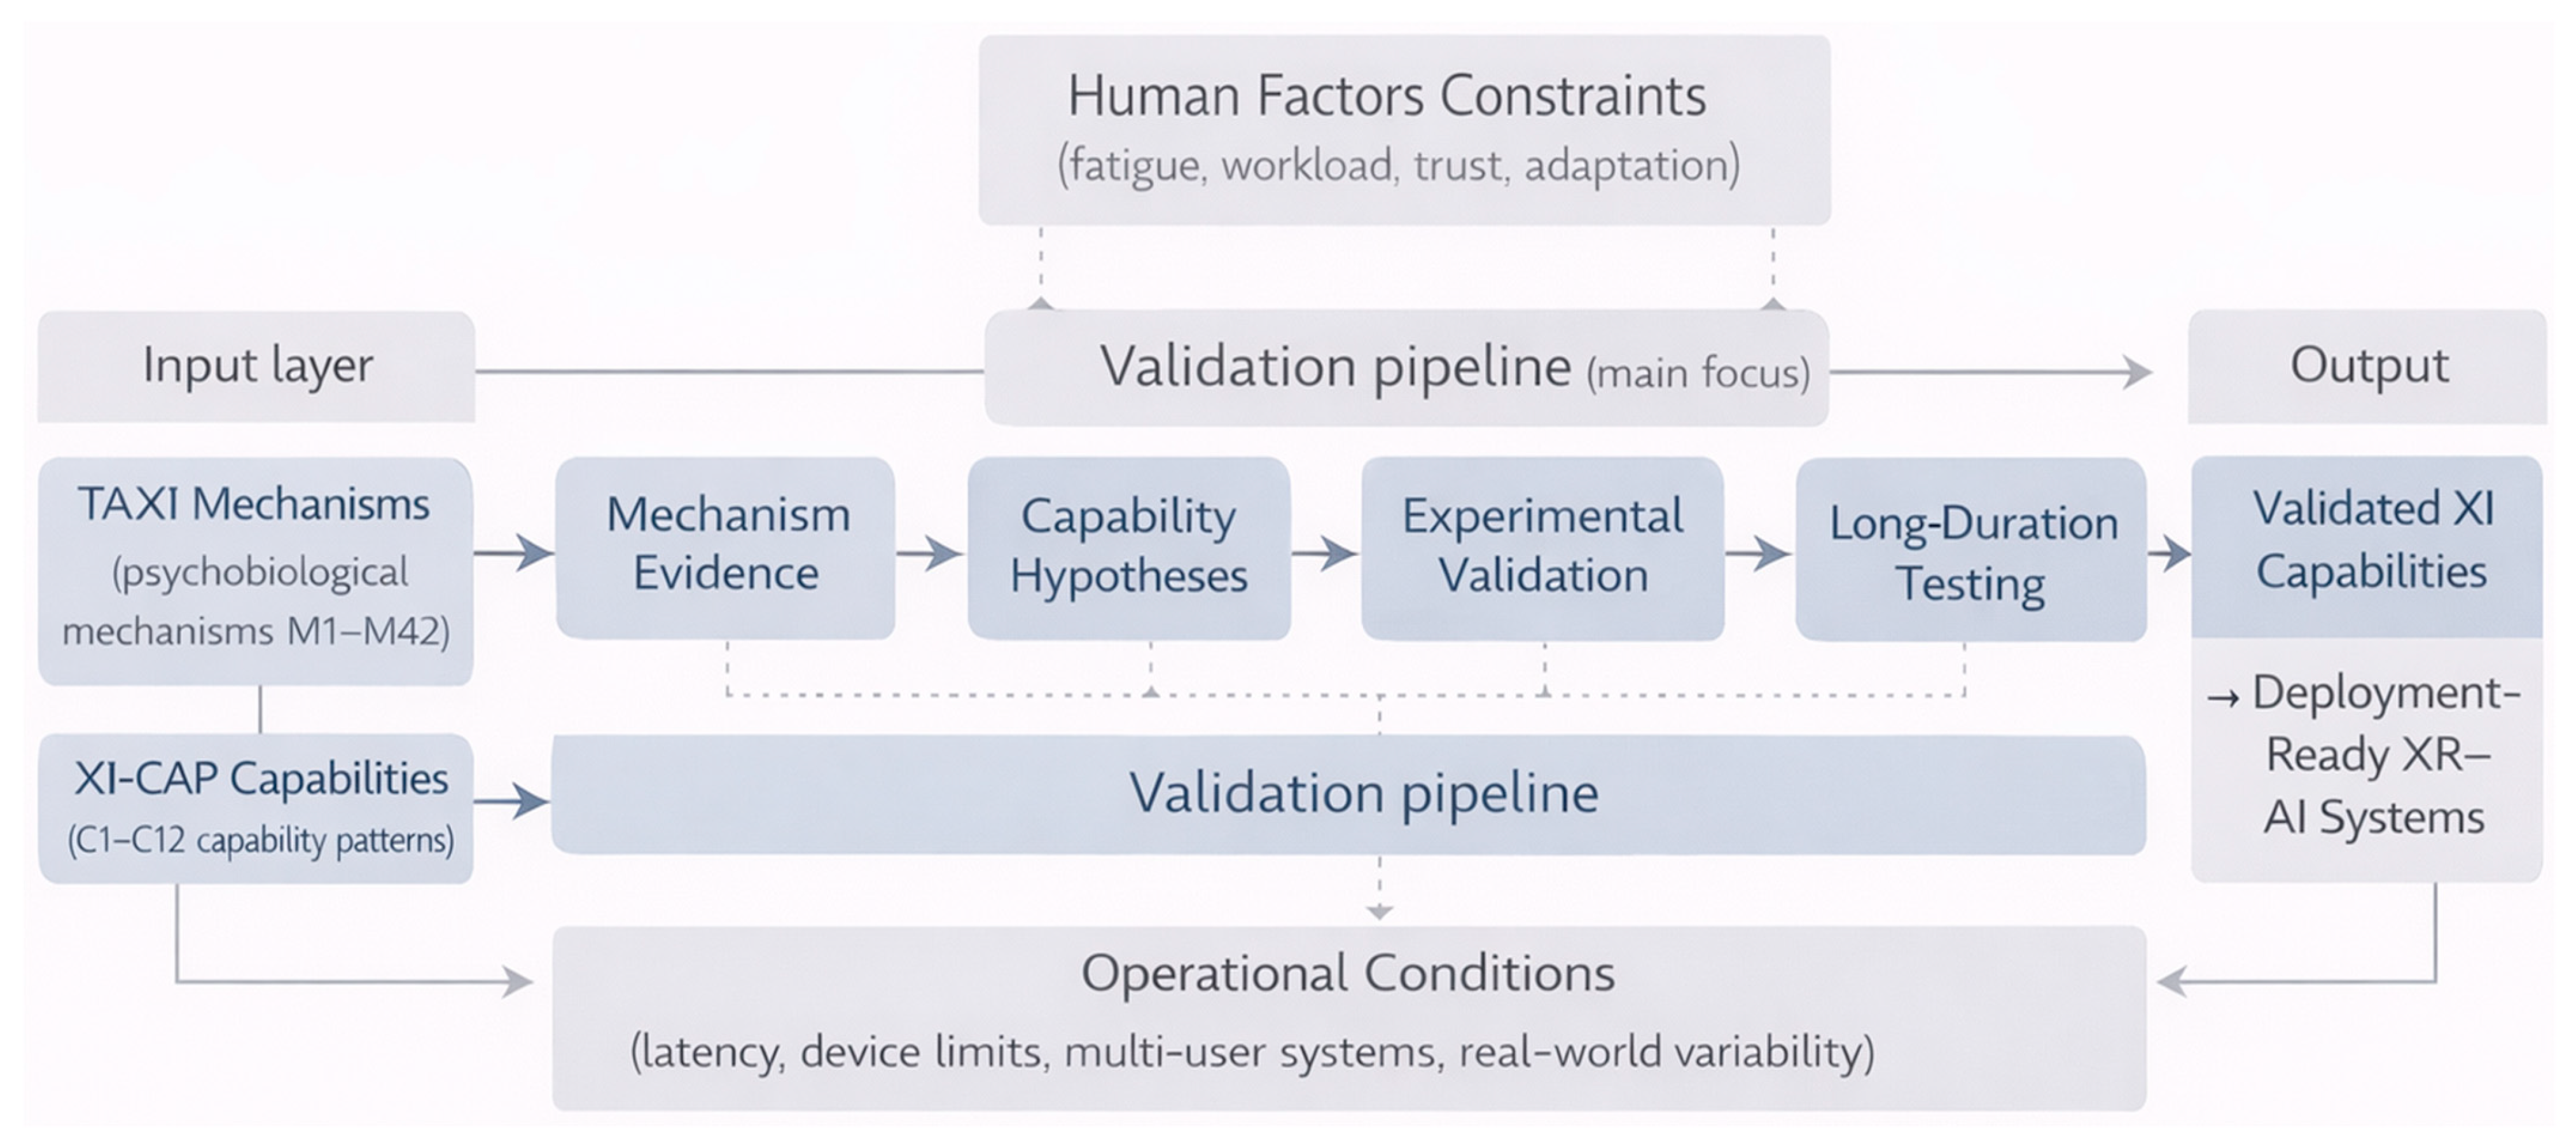
- formulation of a research agenda to validate the XI-CAP constructs.
2.2. Conceptual Scope
- has empirical support in peer-reviewed literature;
- represents a psychobiological or cognitive-behavioral process rather than an application domain;
- is relevant to capability augmentation in immersive or phygital XR–AI environments.
2.3. Construction of the TAXI Mechanism Layer
2.4. Extension Beyond XR to XR-AI
- sustained or repeated exposure;
- high-precision cognitive and motor demands;
- multi-user coordination;
- perception and decision support;
- supervision of remote or simulated systems;
- long-duration workload and fatigue effects.
2.5. Mechanism Inclusion and Distinctness Criteria
- operates at a distinct psychobiological level;
- involves a different causal pathway;
- produces different measurable outcomes;
- cannot be reduced to another mechanism without loss of explanatory clarity.
2.6. Derivation of XI-CAP
- convergence toward a shared functional outcome;
- relevance to high-precision or long-duration tasks;
- plausibility of modulation through immersive system design;
- relevance to real-world deployment constraints.
2.7. Literature Identification
2.8. Evidence Provenance
2.9. Derivation of Research Agenda and Research Priorities
- mechanisms likely to become safety-critical under long-duration use;
- interactions between mechanisms that remain insufficiently validated;
- areas where XR evidence, adjacent disciplines, and XR–AI deployment conditions intersect but remain untested;
- barriers to real-world implementation, including workload stability, trust calibration, coordination, interpretability, and long-term adaptation.
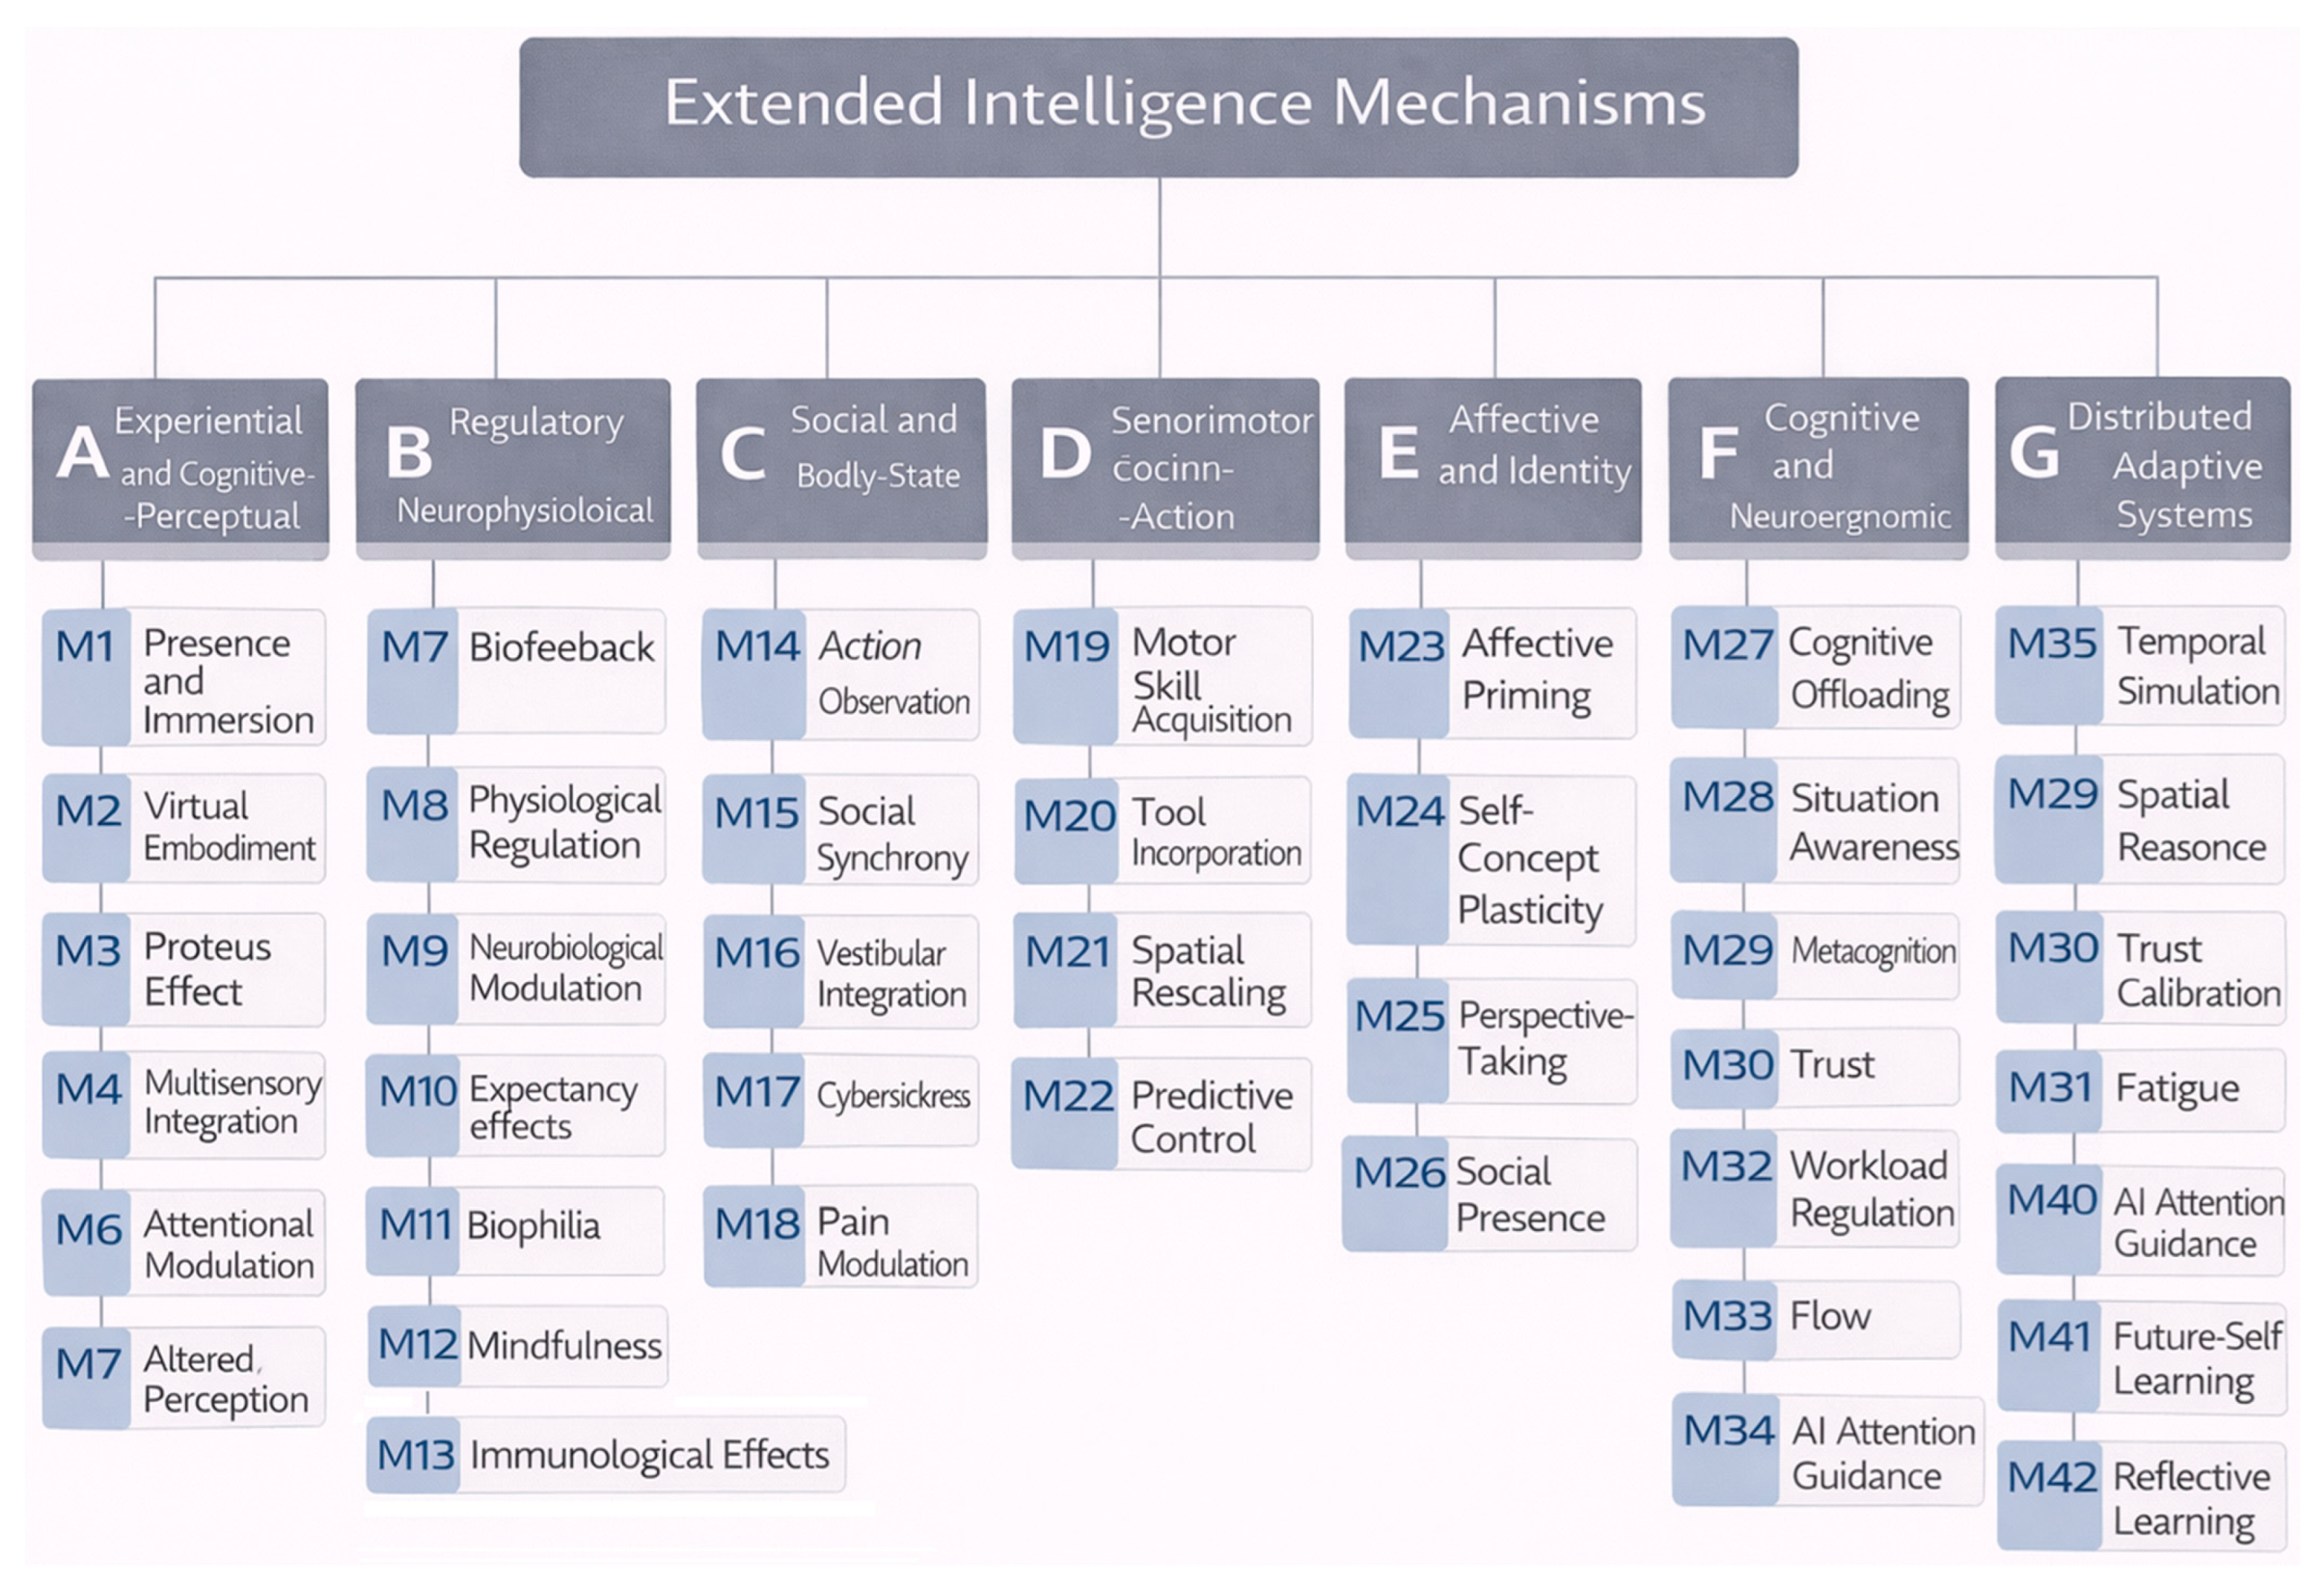
3. Results
- A.
- Experiential and Cognitive–Perceptual Mechanisms (M1–M6)
- B.
- Regulatory and Neurophysiological Mechanisms (M7–M13)
- C.
- Social and Bodily-State Mechanisms (M14–M18)
- D.
- Sensorimotor and Action Mechanisms (M19–M22)
- E.
- Affective and Identity Mechanisms (M23–26)
- F.
- Cognitive and Neuroergonomic Mechanisms (M27–M34)
- G.
- Distributed and Adaptive System Mechanisms (M35–M42)
3.1. TAXI: Source Grounding and Expansion Beyond XR Mechanisms
3.2. TAXI Mechanism Inventory and Presentation Format
- A.
- Experiential and Cognitive–Perceptual Mechanisms: Perception and subjective experience in XR environments, includes M1 Presence and Immersion; M2 Virtual Embodiment; M3 Proteus Effect; M4 Multisensory Integration; M5 Attentional Modulation; M6 Altered Time Perception.
- B.
- Regulatory and Neurophysiological Mechanisms: Physiological and neural state regulation, includes M7 Biofeedback/Neurofeedback Integration; M8 Physiological Regulation; M9 Neurobiological Modulation; M10 Placebo and Expectancy Effects; M11 Biophilia and Nature-Based Effects; M12 Meditation and Mindfulness Effects; M13 Immunological Effects.
- C.
- Social and Bodily-State Mechanisms: Social coordination and bodily stability, includes M14 Action Observation and Imitation Learning; M15 Social Synchrony and Interpersonal Coordination; M16 Vestibular Engagement and Motion Cue Integration; M17 Sensory Conflict and Cybersickness Dynamics; M18 XR-Induced Analgesia and Pain Modulation).
- D.
- Sensorimotor and Action Mechanisms: Motor control and action capability extension, includes M19 Motor Skill Acquisition and Procedural Automation; M20 Tool Incorporation and Agency Extension; M21 Visuospatial Rescaling and Scale Transfer; M22 Predictive Perception and Anticipatory Control.
- E.
- Affective and Identity Mechanisms: Emotion, identity, and social cognition, includes M23 Affective Priming; M24 Self-Concept Plasticity; M25 Perspective-Taking and Moral–Cognitive Modulation; M26 Social Presence and Affective Resonance.
- F.
- Cognitive and Neuroergonomic Mechanisms: Higher-order cognition and performance regulation, includes M27 Cognitive Offloading and Externalized Cognition; M28 Shared Situation Awareness and Distributed Cognition; M29 Metacognitive Calibration and Confidence Regulation; M30 Trust Calibration and Automation Reliance; M31 Fatigue Dynamics and Vigilance Sustainment; M32 Cognitive Workload Regulation; M33 Adaptive Error Shaping and Learning Acceleration; M34 Flow State Induction and Sustained Engagement.
- G.
- Distributed and Adaptive System Mechanisms: Distributed cognition, agency, and long-term adaptation, includes M35 Mental Time Travel and Temporal Simulation; M36 High-Dimensional Abstraction and Spatial Reasoning Support; M37 Parallel Presence and Distributed Attentional Allocation; M38 Delegated Embodiment and Proxy Agency; M39 Attentional Orchestration by Autonomous Agents; M40 Long-Term Neuroplastic Adaptation; M41 Future-Self Embodiment and Motivational Commitment; M42 Replay-Based Self-Modeling and Reflective Learning.
- (A) Experiential and Cognitive–Perceptual Mechanisms

| TAXI Mechanism (No. + Name) | Short Definition | Example XI Use Contexts | Supporting Literature |
|---|---|---|---|
| M1 Presence and Immersion | Subjective sense of “being there” in a virtual environment, eliciting realistic cognitive and physiological responses. | High-fidelity simulation training; digital twin walkthroughs; remote operations requiring perceptual realism. | [46,65,67,71,90,91,92,93,94,95,96] |
| M2 Virtual Embodiment | Sense of ownership and control over a virtual body or body part. | Teleoperation with embodied control; rehabilitation simulation; avatar-based collaboration. | [46,97,98,99,100,101,102] |
| M3 Proteus Effect | Behavioral and cognitive changes driven by avatar characteristics and identity cues. | Role rehearsal; leadership training; bias modulation; identity-based behavioral shaping. | [65,103,104,105] |
| M4 Multisensory Integration | Coherent perception arising from synchronized multimodal sensory input. | Surgical and technical simulation with haptics; multimodal alert systems; accessibility via redundant sensory cues. | [73,106,107,108,109,110,111,112] |
| M5 Attentional Modulation (Distraction and Focus Control) | Allocation and control of attention through salience, sensory load, and task-relevant cues. | Focus guidance in complex interfaces; attentional steering in control systems; distraction-based modulation (e.g., pain reduction). | [73,86,113,114,115,116,117,118] |
| M6 Altered Time Perception | Subjective compression or expansion of perceived time during immersive interaction. | Extended training sessions; sustained monitoring tasks; endurance support in repetitive workflows. | [65,119,120,121] |
- (B) Regulatory and Neurophysiological Mechanisms
| TAXI Mechanism (No. + Name) | Short Definition | Example XI Use Contexts | Supporting Literature |
|---|---|---|---|
| M7 Biofeedback/Neurofeedback Integration | Closed-loop physiological sensing and feedback enabling self-regulation. | HRV/EEG-based stress training; adaptive XR environments responding to user state; performance regulation. | [122,123,124,125,126] |
| M8 Physiological Regulation | Modulation of autonomic and physiological state (e.g., arousal, stress responses) during XR interaction. | Recovery design for high-stress work; resilience training; sustained operational readiness. | [67,86,116,126] |
| M9 Neurobiological Modulation | Changes in neural activation and plasticity associated with learning and cognitive adaptation. | Neuroergonomic optimization; accelerated skill acquisition; cognitive performance tuning. | [67,127,128,129,130] |
| M10 Placebo and Expectancy Effects | Belief-driven modulation of perception, physiology, and performance. | Framing-driven motivation; expectancy-enhanced training; analgesia modulation. | [131,132,133,134] |
| M11 Biophilia and Nature-Based Effects | Stress reduction and cognitive restoration through exposure to natural environments. | Micro-break recovery environments; burnout reduction; wellbeing design in XR workspaces. | [135,136,137,138] |
| M12 Meditation and Mindfulness Effects | Attentional and emotional regulation supported by meditation-based XR interventions. | Readiness priming; stress resilience; cognitive reset before high-demand tasks. | [139,140,141] |
| M13 Immunological Effects | Indirect modulation of immune function through stress and autonomic regulation pathways. | Long-term wellbeing interventions; occupational stress–health mitigation. | [142,143] |
- (C) Social and Bodily-State Mechanisms
| TAXI Mechanism (No. + Name) | Short Definition | Example XI Use Contexts | Supporting Literature |
|---|---|---|---|
| M14 Action Observation and Imitation Learning | Learning through observing and replicating embodied actions. | Remote apprenticeship training; expert-guided skill transfer; AI-generated embodied demonstrations. | [144,145,146] |
| M15 Social Synchrony and Interpersonal Coordination | Temporal and behavioral alignment between individuals supporting coordinated action. | Multi-user assembly; crisis response coordination; time-critical team workflows. | [41,147,148,149,150] |
| M16 Vestibular Engagement and Motion Cue Integration | Integration of vestibular and sensory cues supporting orientation and motion perception. | Flight and vehicle simulation; navigation tasks; telepresence locomotion; orientation training. | [61,63,73,151,152] |
| M17 Sensory Conflict and Cybersickness Dynamics | Adverse physiological responses arising from mismatch between sensory inputs and motion cues. | Long-duration XR use; safety-critical applications; cybersickness mitigation design. | [61,63,66,87,89,152] |
| M18 XR-Induced Analgesia and Pain Modulation | Reduction in pain perception through distraction, embodiment, and affective modulation. | Rehabilitation; procedural tolerance; endurance support in physically demanding tasks. | [67,153,154,155,156] |
- (D) Sensorimotor and Action Mechanisms
| TAXI Mechanism (No. + Name) | Short Definition | Example XI Use Contexts | Supporting Literature |
|---|---|---|---|
| M19 Motor Skill Acquisition and Procedural Automation | Skill learning and procedural memory consolidation through immersive practice. | Surgical simulation; industrial assembly; high-dexterity training; sports skill acquisition. | [67,129,130,157,158] |
| M20 Tool Incorporation and Agency Extension | Integration of external tools into the body schema and control system. | Robot teleoperation; AR-assisted manipulation; exoskeleton control; remote maintenance. | [69,70,78,159,160,161] |
| M21 Visuospatial Rescaling and Scale Transfer | Perception and action across altered spatial scales (micro to macro). | City-scale digital twins; infrastructure inspection; microscale medical visualization; large-scale logistics control. | [18,23,24,162,163,164,165,166] |
| M22 Predictive Perception and Anticipatory Control | Feedforward prediction enabling proactive action and error minimization. | Hazard anticipation; predictive maintenance; time-critical remote operations. | [75,85,163,167,168,169,170] |
- (E) Affective and Identity Mechanisms
| TAXI Mechanism (No. + Name) | Short Definition | Example XI Use Contexts | Supporting Literature |
|---|---|---|---|
| M23 Affective Priming | Modulation of emotional state through immersive cues and environmental design. | De-escalation training; mood regulation for performance; emotional context shaping in collaboration. | [46,65,171,172,173] |
| M24 Self-Concept Plasticity | Changes in self-perception through role adoption and embodied identity. | Confidence building; leadership rehearsal; identity-based training scenarios. | [65,98,103,104,105] |
| M25 Perspective-Taking and Moral–Cognitive Modulation | Modulation of empathy, perspective-taking, and moral reasoning through simulated viewpoint shifts. | Ethics training; policy evaluation; intergroup understanding; conflict mediation. | [37,65,174,175,176] |
| M26 Social Presence and Affective Resonance | Perceived co-presence and emotional attunement between individuals in XR environments. | Remote teamwork; telemedicine; distributed leadership; collaborative negotiation. | [46,147,148,149,177,178] |
- (F) Cognitive and Neuroergonomic Mechanisms
| TAXI Mechanism (No. + Name) | Short Definition | Example XI Use Contexts | Supporting Literature |
|---|---|---|---|
| M27 Cognitive Offloading and Externalized Cognition | Use of external representations or AI to support memory, reasoning, and task execution. | Guidance overlays; procedural checklists; annotated digital twins. | [69,75,85,159,179] |
| M28 Shared Situation Awareness and Distributed Cognition | Alignment of mental models across individuals enabling coordinated understanding and decision-making. | Multi-team coordination; digital twin operations centers; distributed mission planning; real-time collaborative decision-making in complex environments. | [41,69,75,81,85,180] |
| M29 Metacognitive Calibration and Confidence Regulation | Alignment between confidence and actual performance through feedback and self-monitoring. | Competency validation; reducing overconfidence; operator self-check workflows. | [143,163,170,181,182,183] |
| M30 Trust Calibration and Automation Reliance | Adjustment of reliance on AI systems to avoid overuse or underuse. | AI copilots; explainable decision support; supervisory control and override training. | [37,49,75,85,184,185] |
| M31 Fatigue Dynamics and Vigilance Sustainment | Changes in alertness and vigilance over time during prolonged task engagement. | Long-duration monitoring; control rooms; transport safety operations. | [86,114,186,187] |
| M32 Cognitive Workload Regulation (Neuroergonomic Load Shaping) | Adjustment of task demand and information load to maintain performance. | Adaptive interfaces; complexity management; multitask coordination. | [42,75,86,114,116] |
| M33 Adaptive Error Shaping and Learning Acceleration | Use of adaptive feedback and task difficulty to optimize learning and performance improvement. | Intelligent tutoring; adaptive simulators; accelerated skill acquisition. | [129,130,158,188,189] |
| M34 Flow State Induction and Sustained Engagement | Facilitation of deep engagement and sustained high-performance states. | Long-duration complex tasks; training adherence; creative problem solving. | [65,189,190,191] |
- (G) Distributed and Adaptive System Mechanisms
| TAXI Mechanism (No. + Name) | Short Definition | Example XI Use Contexts | Supporting Literature |
|---|---|---|---|
| M35 Mental Time Travel and Temporal Simulation | Simulation of past experiences and possible future scenarios in an embodied form. | Scenario planning; disaster rehearsal; strategic foresight. | [65,192,193] |
| M36 High-Dimensional Abstraction and Spatial Reasoning Support | Understanding complex systems through spatialized and high-dimensional representations. | AI model interpretability; complex systems education; industrial and scientific visualization. | [20,92,162,163,164] |
| M37 Parallel Presence and Distributed Attentional Allocation | Allocation of attention across multiple environments or representations simultaneously. | Multi-site monitoring; distributed supervision; simultaneous remote inspection. | [81,96,114,170,194] |
| M38 Delegated Embodiment and Proxy Agency | Delegation of actions to agents or avatars operating on user intent. | Agent-based monitoring; smart-city delegation; escalation management. | [33,70,195,196,197] |
| M39 Attentional Orchestration by Autonomous Agents | AI-driven prioritization and direction of user attention toward relevant events. | Safety monitoring; predictive alerting; operations center triage. | [33,75,85,170,185] |
| M40 Long-Term Neuroplastic Adaptation | Persistent neural changes resulting from repeated XR interaction. | Long-term training; workforce upskilling; sustained XR use. | [67,127,128,130] |
| M41 Future-Self Embodiment and Motivational Commitment | Changes in motivation driven by embodied simulation of future selves. | Health adherence; sustainability behavior; long-term goal reinforcement. | [65,189,198] |
| M42 Replay-Based Self-Modeling and Reflective Learning | Learning through replay, embodied review, and self-model refinement. | Training debrief; expert coaching; post-incident analysis. | [129,130,188,199] |
3.3. Interpretation, Scope, and Evidentiary Status of the TAXI Inventory
4. Extended Intelligence Capability Augmentation Patterns (XI-CAP)
4.1. From Psychobiological Mechanisms to Capability Constructs
- convergence of multiple validated TAXI mechanisms toward a shared functional outcome;
- relevance to observable performance outcomes in XR–AI or human-factors contexts;
- applicability to realistic deployment scenarios, including high-precision, long-duration, or distributed tasks;
- non-reducibility to a single mechanism without loss of explanatory clarity;
- potential for empirical evaluation using behavioral, physiological, or task-performance measures.
4.2. XI Capability Augmentation Patterns (XI-CAP)
4.3. Mapping Mechanisms to Capability Patterns
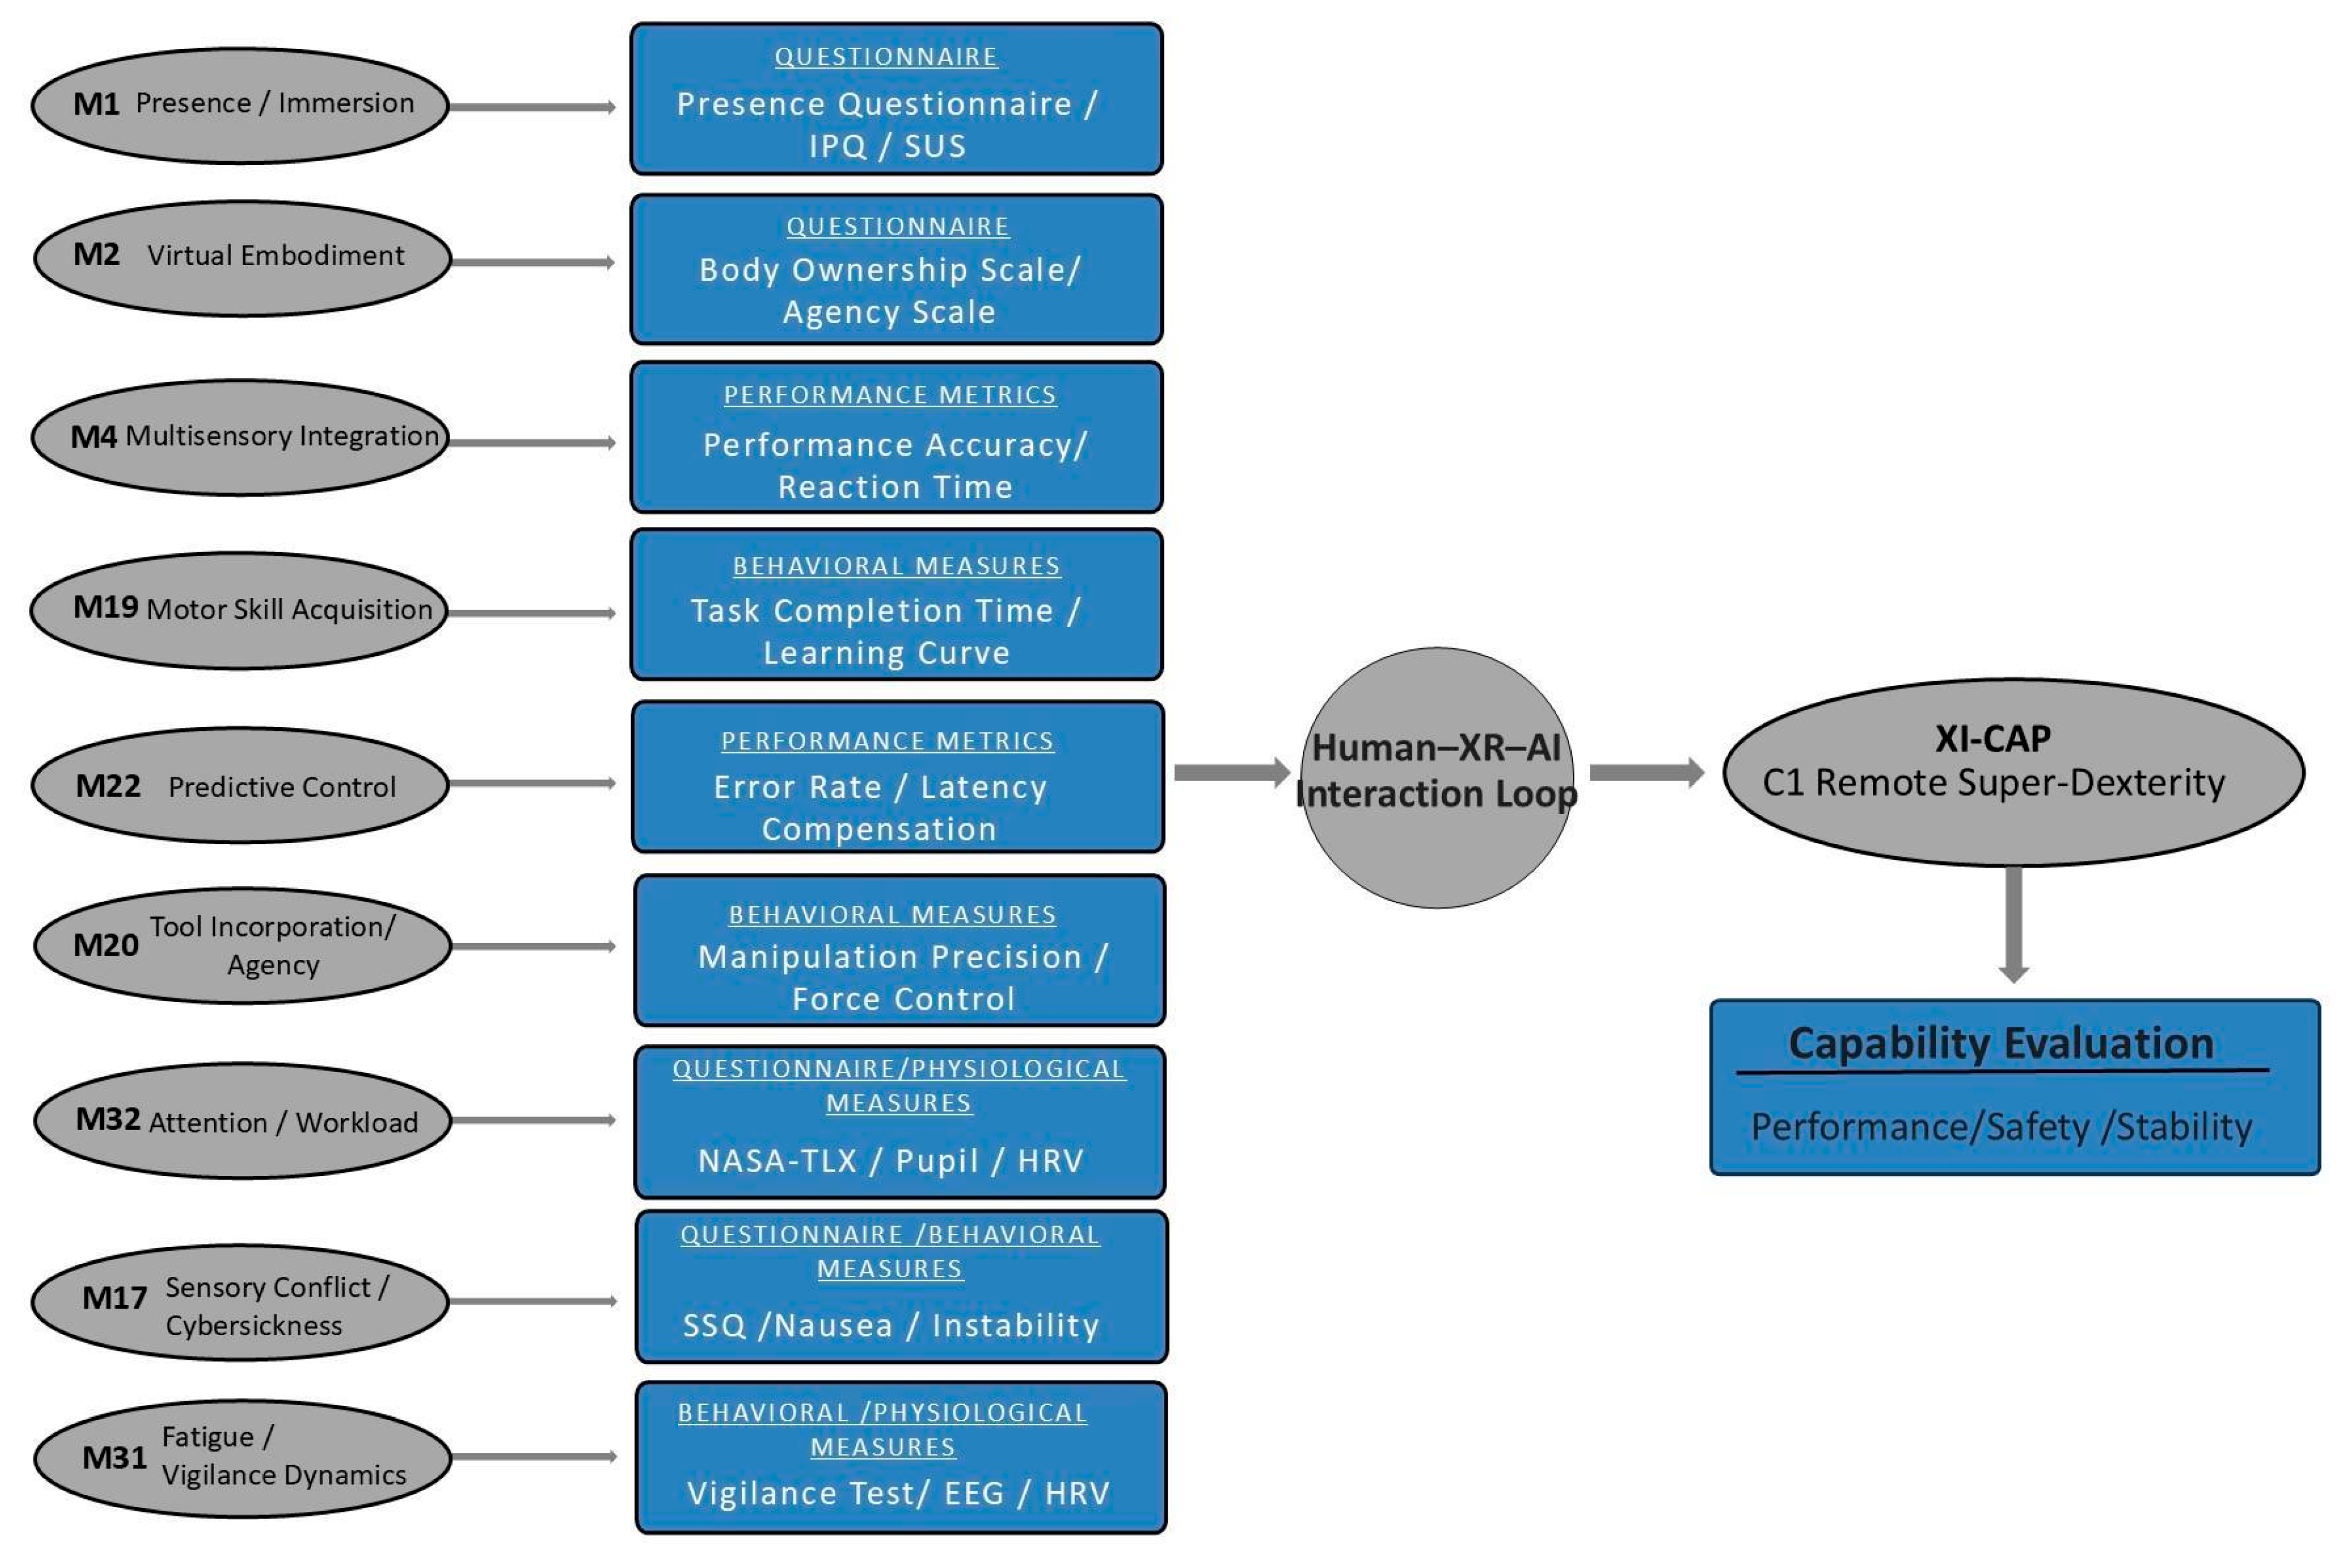
4.4. Operationalizing XI-CAP Constructs
- selecting a target capability (e.g., remote super-dexterity);
- identifying the contributing TAXI mechanisms;
- defining measurable variables for each mechanism (e.g., task accuracy, physiological load, latency tolerance); and
- evaluating their combined effect under controlled or ecologically valid conditions.
5. Research Agenda: Priorities for Validating and Scaling XI
5.1. Research Priorities
5.2. Toward Integrative, Interdisciplinary Research Infrastructures
5.3. Stakeholder Alignment and Translational Relevance
6. Conclusions
Supplementary Materials
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Acknowledgments
Conflicts of Interest
Abbreviations
| AI | Artificial Intelligence |
| AR | Augmented Reality |
| CPS | Cyber-Physical Systems |
| HCI | Human–Computer Interaction |
| HRI | Human–Robot Interaction |
| ITU | International Telecommunication Union |
| MR | Mixed Reality |
| MXR | Medical eXtended Reality |
| OECD | Organisation for Economic Co-operation and Development |
| PRISMA | Preferred Reporting Items for Systematic Reviews and Meta-Analyses |
| TAXI | Taxonomy of eXtended Intelligence |
| VR | Virtual Reality |
| XI | eXtended Intelligence |
| XI-CAP | eXtended Intelligence Capability Augmentation Patterns |
| XR | eXtended Reality |
| XRSI | XR Safety Initiative |
References
- Bush, V. As we may think. Atl. Mon. 1945, 176, 101–108. [Google Scholar]
- Engelbart, D.C. Augmenting Human Intellect: A Conceptual Framework; Stanford Research Institute: Menlo Park, CA, USA, 1962. [Google Scholar]
- Nelson, T.H. Complex information processing: A file structure for the complex, the changing and the indeterminate. In Proceedings of the 20th National Conference of the Association for Computing Machinery, Cleveland, OH, USA, 24–26 August 1965; pp. 84–100. [Google Scholar] [CrossRef] [Scilit]
- Nelson, T.H. Computer Lib/Dream Machines; Microsoft Press: Redmond, WA, USA, 1974. [Google Scholar]
- Berners-Lee, T. Information Management: A Proposal; CERN: Geneva, Switzerland, 1989. [Google Scholar]
- Hinton, C.H. A New Era of Thought; Swan Sonnenschein & Co.: London, UK, 1888. [Google Scholar]
- Rheingold, H. Virtual Reality; Summit Books: New York, NY, USA, 1991. [Google Scholar]
- Lanier, J. Virtual reality: The promise of the future. Interact. Learn. Int. 1992, 8, 275–279. [Google Scholar]
- Lanier, J.; Biocca, F. An insider’s view of the future of virtual reality. J. Commun. 1992, 42, 150–172. [Google Scholar] [CrossRef] [Scilit]
- Gibson, W. Neuromancer; Ace Books: New York, NY, USA, 1984. [Google Scholar]
- Gore, A. Infrastructure for the global village. Sci. Am. 1991, 265, 150–153. [Google Scholar]
- Gelernter, D. Mirror Worlds: Or the Day Software Puts the Universe in a Shoebox... How It Will Happen and What It Will Mean; Oxford University Press: Oxford, UK, 1991. [Google Scholar]
- UNESCO. The Virtual Silk Road Initiative; UNESCO: Paris, France, 1998. [Google Scholar]
- Cheney, C. China’s Digital Silk Road: Strategic Technological Competition and Exporting Political Illiberalism—Challenges for the US. In Issues & Insights; Pacific Forum: Honolulu, HI, USA, 2019; Volume 19, No. WP8, Available online: https://pacforum.org/wp-content/uploads/2019/08/issuesinsights_Vol19-WP8FINAL.pdf (accessed on 12 February 2026).
- Stephenson, N. Snow Crash; Bantam Books: New York, NY, USA, 1992. [Google Scholar]
- Smart, J. The Metaverse Roadmap: Pathways to the 3D Web; Acceleration Studies Foundation: Los Gatos, CA, USA, 2007. [Google Scholar]
- Papagiannis, H. Augmented Human: How Technology is Shaping the New Reality; O’Reilly Media: Sebastopol, CA, USA, 2017. [Google Scholar]
- Ball, M. The Metaverse: And How it Will Revolutionize Everything; W.W. Norton & Company: New York, NY, USA, 2022. [Google Scholar]
- Milgram, P.; Kishino, F. A taxonomy of mixed reality visual displays. IEICE Trans. Inf. Syst. 1994, E77-D, 1321–1329. [Google Scholar]
- Azuma, R.T. A survey of augmented reality. Presence Teleoper. Virtual Environ. 1997, 6, 355–385. [Google Scholar] [CrossRef] [Scilit]
- Lee, L.-H.; Braud, T.; Zhou, P.; Wang, L.; Xu, D.; Lin, Z.; Kumar, A.; Bermejo, C.; Hui, P. All One Needs to Know about Metaverse: A Complete Survey on Technological Singularity, Virtual Ecosystem, and Research Agenda. Found. Trends Hum.-Comput. Interact. 2024, 18, 100–337. [Google Scholar] [CrossRef] [Scilit]
- Organisation for Economic Co-operation and Development. Virtual Worlds and the Metaverse; OECD: Paris, France, 2023. [Google Scholar]
- Grieves, M.; Vickers, J. Digital twin: Mitigating unpredictable, undesirable emergent behavior in complex systems. In Transdisciplinary Perspectives on Complex Systems: New Findings and Approaches; Springer: Cham, Switzerland, 2017; pp. 85–113. [Google Scholar]
- Fuller, A.; Fan, Z.; Day, C.; Barlow, C. Digital twin: Enabling technologies, challenges and open research. IEEE Access 2020, 8, 108952–108971. [Google Scholar] [CrossRef] [Scilit]
- U.S. National Information Infrastructure Task Force. The National Information Infrastructure: Agenda for Action; U.S. Government Printing Office: Washington, DC, USA, 1993.
- Lee, N. Unreal engine, a 3D game engine. In Encyclopedia of Computer Graphics and Games; Springer: Cham, Switzerland, 2023. [Google Scholar] [CrossRef] [Scilit]
- Unity Technologies. Unity Real-Time Development Platform (Unity Engine) [Software]; Unity Technologies: San Francisco, CA, USA, 2023; Available online: https://unity.com (accessed on 12 February 2026).
- International Energy Agency. Energy Technology Perspectives 2022: Digitalisation and Energy Systems; IEA: Paris, France, 2022. [Google Scholar]
- Minsky, M. The Society of Mind; Simon & Schuster: New York, NY, USA, 1986. [Google Scholar]
- Russell, S.J.; Norvig, P. Artificial Intelligence: A Modern Approach, 4th ed.; Pearson: Harlow, UK, 2021. [Google Scholar]
- Yao, S.; Zhao, J.; Yu, D.; Du, N.; Shafran, I.; Narasimhan, K.; Cao, Y. ReAct: Synergizing reasoning and acting in language models. In Proceedings of the International Conference on Learning Representations, Kigali, Rwanda, 1–5 May 2023. [Google Scholar]
- Schick, T.; Dwivedi-Yu, J.; Dessì, R.; Raileanu, R.; Lomeli, M.; Zettlemoyer, L.; Cancedda, N.; Scialom, T. Toolformer: Language models can teach themselves to use tools. arXiv 2023, arXiv:2302.04761. [Google Scholar] [CrossRef] [Scilit]
- Shinn, N.; Cassano, F.; Gopinath, A.; Narasimhan, K.R.; Yao, S. Reflexion: Language agents with verbal reinforcement learning. In Proceedings of the Advances in Neural Information Processing Systems, New Orleans, LA, USA, 10–16 December 2023. [Google Scholar]
- Wu, Q.; Bansal, G.; Zhang, J.; Wu, Y.; Li, B.; Zhu, E.; Jiang, L.; Zhang, X.; Zhang, S.; Liu, J.; et al. AutoGen: Enabling next-generation large language model applications via multi-agent conversation. arXiv 2023, arXiv:2308.08155. [Google Scholar] [CrossRef] [Scilit]
- Ito, J. Extended Intelligence. 2016. Available online: https://pubpub.ito.com/pub/extended-intelligence (accessed on 12 February 2026).
- Bao, Y.; Gong, W.; Yang, K. A literature review of human–AI synergy in decision making: From the perspective of affordance actualization theory. Systems 2023, 11, 442. [Google Scholar] [CrossRef] [Scilit]
- Floridi, L.; Cowls, J.; Beltrametti, M.; Chatila, R.; Chazerand, P.; Dignum, V.; Luetge, C.; Madelin, R.; Pagallo, U.; Rossi, F.; et al. AI4People—An ethical framework for a good artificial intelligence society: Opportunities, risks, principles, and recommendations. Minds Mach. 2018, 28, 689–707. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wienrich, C.; Latoschik, M.E. Congruence and plausibility, not presence: Pivotal conditions for extended reality experiences and effects. Front. Virtual Real. 2022, 3, 819048. [Google Scholar] [CrossRef] [Scilit]
- Reiners, T.; Wood, L.C.; Gregory, S.; Teräs, M.; Chang, V.; Hill, C. The role of immersive technologies in education: Extended reality and beyond. Educ. Sci. 2020, 10, 153. [Google Scholar] [CrossRef] [Scilit]
- Akhtar, Z.; Rawol, A. Uncovering cybersecurity vulnerabilities: A Kali Linux investigative exploration perspective. Int. J. Adv. Netw. Monit. Controls 2024, 9, 11–22. [Google Scholar] [CrossRef] [Scilit]
- Woolley, A.W.; Chabris, C.F.; Pentland, A.; Hashmi, N.; Malone, T.W. Evidence for a collective intelligence factor in the performance of human groups. Science 2010, 330, 686–688. [Google Scholar] [CrossRef] [Scilit]
- Schmorrow, D.D.; Fidopiastis, C.M. (Eds.) Foundations of Augmented Cognition; Springer: Cham, Switzerland, 2015. [Google Scholar] [CrossRef] [Scilit]
- Goertzel, B.; Pennachin, C. (Eds.) Artificial General Intelligence; Springer: Berlin, Germany, 2007. [Google Scholar]
- Topol, E.J. Deep Medicine: How Artificial Intelligence Can Make Healthcare Human Again; Basic Books: New York, NY, USA, 2019. [Google Scholar]
- Slater, M. Place illusion and plausibility can lead to realistic behaviour in immersive virtual environments. Philos. Trans. R. Soc. B Biol. Sci. 2009, 364, 3549–3557. [Google Scholar] [CrossRef] [Scilit]
- Slater, M.; Sanchez-Vives, M.V. Enhancing our lives with immersive virtual reality. Front. Robot. AI 2016, 3, 74. [Google Scholar] [CrossRef] [Scilit]
- Spiegel, B.M.R.; Rizzo, A.; Persky, S.; Liran, O.; Wiederhold, B.; Woods, S.; Donovan, K.; Sarkar, K.; Xiang, H.; Joo, S.; et al. What is medical extended reality? A taxonomy defining the current breadth and depth of an evolving field. J. Med. Ext. Real. 2024, 1, 4–12. [Google Scholar] [CrossRef] [Scilit]
- Eyal, N. Hooked: How to Build Habit-Forming Products; Penguin: New York, NY, USA, 2014. [Google Scholar]
- Office of the Surgeon General. Social Media and Youth Mental Health: The U.S. Surgeon General’s Advisory; U.S. Department of Health and Human Services: Washington, DC, USA, 2023.
- National Press and Publication Administration. Notice on Further Strictly Managing and Effectively Preventing Minors from Indulging in Online Games. 2021. Available online: http://www.nppa.gov.cn (accessed on 12 February 2026).
- Office of the eSafety Commissioner. Online Safety Research Program: Youth, Social Media and Wellbeing; Australian Government: Canberra, Australia, 2023.
- Floridi, L.; Cowls, J. A unified framework of five principles for artificial intelligence in society. Harv. Data Sci. Rev. 2019, 1, 535–545. [Google Scholar] [CrossRef] [Scilit]
- Di Summa, M.; Reno, V.; Dibari, P.; Pernisco, G.; Sacco, M.; Stella, E. Extended reality and artificial intelligence: Synergic approaches in real world applications. In Roadmapping Extended Reality: Fundamentals and Applications; Alcañiz, M., Sacco, M., Tromp, J.G., Eds.; John Wiley & Sons: Hoboken, NJ, USA, 2022; pp. 143–156. [Google Scholar] [CrossRef] [Scilit]
- Bekaroo, G.; Sungkur, R.; Ramsamy, P. Augmented reality, virtual reality and mixed reality: Emerging technologies and ethical issues. In Proceedings of the IEEE International Conference on Emerging Technologies, Torino, Italy, 4–7 September 2018. [Google Scholar]
- Orben, A. Teenagers, screens and social media: A narrative review of reviews and key studies. Soc. Psychiatry Psychiatr. Epidemiol. 2020, 55, 407–414. [Google Scholar] [CrossRef] [Scilit]
- XR Safety Initiative. The XRSI Privacy and Safety Framework; XR Safety Initiative: 2021. Available online: https://xrsi.org (accessed on 12 February 2026).
- International Telecommunication Union. Global Digital Trends and Policy Recommendations for Immersive Technologies; International Telecommunication Union: Geneva, Switzerland, 2024. [Google Scholar]
- Kourtesis, P.; Linnell, J.; Amir, R.; MacPherson, S.E. Cybersickness in virtual reality: A systematic review and meta-analysis. Neurosci. Biobehav. Rev. 2023, 150, 105179. [Google Scholar] [CrossRef] [Scilit]
- Grandjean, E. Ergonomics in Computerized Offices; Taylor & Francis: London, UK, 1987. [Google Scholar]
- Hedge, A. Ergonomic Workplace Design for Health, Wellness, and Productivity; CRC Press: Boca Raton, FL, USA, 2016. [Google Scholar]
- Reason, J.T.; Brand, J.J. Motion Sickness; Academic Press: London, UK, 1975. [Google Scholar]
- Keshavarz, B.; Hecht, H. Validating an efficient method to quantify motion sickness. Hum. Factors 2011, 53, 415–426. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- LaViola, J.J. A discussion of cybersickness in virtual environments. SIGCHI Bull. 2000, 32, 47–56. [Google Scholar] [CrossRef] [Scilit]
- Rebenitsch, L.; Owen, C. Review on cybersickness in applications and visual displays. Virtual Real. 2016, 20, 101–125. [Google Scholar] [CrossRef] [Scilit]
- Bailenson, J.N. Experience on Demand: What Virtual Reality Is, How it Works, and What It Can Do; W.W. Norton & Company: New York, NY, USA, 2018. [Google Scholar]
- Stanney, K.M.; Lawson, B.D.; Rokers, B.; Dennison, M.S.; Fidopiastis, C.M.; Stoffregen, T.A.; Weech, S.; Fulvio, J.M. Identifying causes of and solutions for cybersickness in immersive technology: Reformulation of a research and development agenda. Int. J. Hum.-Comput. Interact. 2020, 36, 1783–1803. [Google Scholar] [CrossRef] [Scilit]
- Cummings, J.J.; Bailenson, J.N. How immersive is enough? A meta-analysis of the effect of immersive technology on user presence. Media Psychol. 2016, 19, 272–309. [Google Scholar] [CrossRef] [Scilit]
- Riva, G.; Wiederhold, B.K.; Mantovani, F. Neuroscience of virtual reality: From virtual exposure to embodied medicine. Cyberpsychol. Behav. Soc. Netw. 2019, 22, 82–96. [Google Scholar] [CrossRef] [Scilit]
- Hollan, J.; Hutchins, E.; Kirsh, D. Distributed cognition: Toward a new foundation for human–computer interaction research. ACM Trans. Comput.-Hum. Interact. 2000, 7, 174–196. [Google Scholar] [CrossRef] [Scilit]
- Goodrich, M.A.; Schultz, A.C. Human–robot interaction: A survey. Found. Trends Hum.-Comput. Interact. 2007, 1, 203–275. [Google Scholar] [CrossRef] [Scilit]
- Slater, M.; Wilbur, S. A framework for immersive virtual environments (FIVE): Speculations on the role of presence in virtual environments. Presence Teleoper. Virtual Environ. 1997, 6, 603–616. [Google Scholar] [CrossRef] [Scilit]
- Witmer, B.G.; Singer, M.J. Measuring presence in virtual environments: A presence questionnaire. Presence Teleoper. Virtual Environ. 1998, 7, 225–240. [Google Scholar] [CrossRef] [Scilit]
- Kennedy, R.S.; Lane, N.E.; Berbaum, K.S.; Lilienthal, M.G. Simulator sickness questionnaire: An enhanced method for quantifying simulator sickness. Int. J. Aviat. Psychol. 1993, 3, 203–220. [Google Scholar] [CrossRef] [Scilit]
- Jerald, J. The VR Book: Human-Centered Design for Virtual Reality; Morgan & Claypool: San Rafael, CA, USA, 2015. [Google Scholar]
- Parasuraman, R.; Sheridan, T.B.; Wickens, C.D. A model for types and levels of human interaction with automation. IEEE Trans. Syst. Man Cybern. A 2000, 30, 286–297. [Google Scholar] [CrossRef] [Scilit]
- Levac, D.; Huber, M.; Sternad, D. Learning and transfer of complex motor skills in virtual reality: A perspective review. J. Neuroeng. Rehabil. 2019, 16, 121. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Oh, C.S.; Bailenson, J.N.; Welch, G.F. A systematic review of social presence: Definition, antecedents, and implications. Front. Robot. AI 2018, 5, 114. [Google Scholar] [CrossRef] [Scilit]
- Haggard, P. Sense of agency in the human brain. Nat. Rev. Neurosci. 2017, 18, 196–207. [Google Scholar] [CrossRef] [Scilit]
- Tromp, J.G. Extended reality and the backbone: Towards a 3D mirrorworld. In Roadmapping Extended Reality; Alcañiz, M., Sacco, M., Tromp, J.G., Eds.; Scrivener: Beverly, MA, USA, 2022; pp. 193–227. [Google Scholar]
- Tromp, J.G.; Zachmann, G.; Perret, J.; Palacco, B. Future directions for extended reality 2021–2030: International Delphi consensus study. In Roadmapping Extended Reality; Alcañiz, M., Sacco, M., Tromp, J.G., Eds.; Scrivener: Beverly, MA, USA, 2022; pp. 1–34. [Google Scholar]
- Batty, M.; Axhausen, K.W.; Giannotti, F.; Pozdnoukhov, A.; Bazzani, A.; Wachowicz, M.; Ouzounis, G.; Portugali, Y. Smart cities of the future. Eur. Phys. J. Spec. Top. 2012, 214, 481–518. [Google Scholar] [CrossRef] [Scilit]
- Arlati, S.; Borghetti, D. XR and neurorehabilitation. In Roadmapping Extended Reality: Fundamentals and Applications; Alcañiz, M., Sacco, M., Tromp, J.G., Eds.; John Wiley & Sons: Hoboken, NJ, USA, 2022; pp. 257–282. [Google Scholar] [CrossRef] [Scilit]
- Eraslan, E.; Yildiz, Y.; Annaswamy, A.M.; Cecil, J.; Gupta, A. CPHS–XR: A Unifying Framework for Understanding Cyber Physical Human Systems in the Realm of Extended Reality. In HCI International 2025 – Late Breaking Papers: 27th International Conference on Human-Computer Interaction, HCII 2025, Gothenburg, Sweden, 22–27 June 2025, Proceedings, Part VIII; Springer: Berlin/Heidelberg, Germany, 2025; pp. 36–48. [Google Scholar] [CrossRef] [Scilit]
- Sha, L.; Gopalakrishnan, S.; Liu, X.; Wang, Q. Cyber-physical systems: A new frontier. In Machine Learning and Autonomous Systems; Springer: Cham, Switzerland, 2020; pp. 3–13. [Google Scholar] [CrossRef] [Scilit]
- Endsley, M.R. From here to autonomy: Lessons learned from human–automation research. Hum. Factors 2017, 59, 5–27. [Google Scholar] [CrossRef] [Scilit]
- Dehais, F.; Lafont, A.; Roy, R.; Fairclough, S. A neuroergonomics approach to mental workload, engagement and human performance. Front. Neurosci. 2020, 14, 268. [Google Scholar] [CrossRef] [Scilit]
- Mondellini, M.; Colombo, V.; Arlati, S.; Lawson, G.; Cobb, S. Extended reality for smart cities and digital twins. In Roadmapping Extended Reality: Fundamentals and Applications; Alcañiz, M., Sacco, M., Tromp, J.G., Eds.; John Wiley & Sons: Hoboken, NJ, USA, 2022; pp. 229–256. [Google Scholar] [CrossRef] [Scilit]
- Center, E.G.; Mimnaugh, K.; Häkkinen, J.; LaValle, S.M. Perception engineering and multisensory realism in extended reality. In Roadmapping Extended Reality: Fundamentals and Applications; Alcañiz, M., Sacco, M., Tromp, J.G., Eds.; John Wiley & Sons: Hoboken, NJ, USA, 2022; pp. 157–181. [Google Scholar] [CrossRef] [Scilit]
- Chang, E.; Kim, H.T.; Yoo, B. Virtual reality sickness: A review of causes and measurements. Int. J. Hum.-Comput. Interact. 2020, 36, 1658–1682. [Google Scholar] [CrossRef] [Scilit]
- Slater, M. Measuring presence: A response to the Witmer and Singer presence questionnaire. Presence Teleoper. Virtual Environ. 1999, 8, 560–565. [Google Scholar] [CrossRef] [Scilit]
- Lombard, M.; Ditton, T. At the heart of it all: The concept of presence. J. Comput.-Mediat. Commun. 1997, 3, JCMC321. [Google Scholar] [CrossRef] [Scilit]
- Slater, M.; Usoh, M.; Steed, A. The influence of a virtual body on presence in immersive virtual environments. Presence Teleoper. Virtual Environ. 2000, 9, 413–434. [Google Scholar] [CrossRef] [Scilit]
- Schubert, T.; Friedmann, F.; Regenbrecht, H. The experience of presence: Factor analytic insights. Presence Teleoper. Virtual Environ. 2001, 10, 266–281. [Google Scholar] [CrossRef] [Scilit]
- Grassini, S.; Laumann, K. Questionnaire measures and physiological correlates of presence: A systematic review. Front. Psychol. 2020, 11, 349. [Google Scholar] [CrossRef] [Scilit]
- Wirth, W.; Hartmann, T.; Böcking, S.; Vorderer, P.; Klimmt, C.; Schramm, H.; Saari, T.; Laarni, J.; Ravaja, N.; Gouveia, F.R.; et al. A process model of the formation of spatial presence experiences. Media Psychol. 2007, 9, 493–525. [Google Scholar] [CrossRef] [Scilit]
- Mynick, A.; Steel, A.; Jayaraman, A.; Botch, T.L.; Burrows, A.; Robertson, C.E. Memory-based predictions prime perceptual judgments across head turns in immersive, real-world scenes. Curr. Biol. 2025, 35, 121–130.e6. [Google Scholar] [CrossRef] [Scilit]
- Kilteni, K.; Groten, R.; Slater, M. The sense of embodiment in virtual reality. Presence Teleoper. Virtual Environ. 2012, 21, 373–387. [Google Scholar] [CrossRef] [Scilit]
- Slater, M.; Spanlang, B.; Sanchez-Vives, M.V.; Blanke, O. First person experience of body transfer in virtual reality. PLoS ONE 2010, 5, e10564. [Google Scholar] [CrossRef] [Scilit]
- Slater, M.; Perez-Marcos, D.; Ehrsson, H.H.; Sanchez-Vives, M.V. Towards a digital body: The virtual arm illusion. Front. Hum. Neurosci. 2008, 2, 6. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Banakou, D.; Groten, R.; Slater, M. Illusory ownership of a virtual child body causes overestimation of object sizes. Proc. Natl. Acad. Sci. USA 2013, 110, 12846–12851. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Gonzalez-Franco, M.; Peck, T.C. Avatar embodiment: A standardized questionnaire. Front. Robot. AI 2018, 5, 74. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Moseley, G.L.; Gallace, A.; Spence, C. Bodily illusions in health and disease: Physiological and clinical perspectives and the concept of a cortical ‘body matrix’. Neurosci. Biobehav. Rev. 2012, 36, 34–46. [Google Scholar] [CrossRef] [Scilit]
- Yee, N.; Bailenson, J.N. The Proteus effect: The effect of transformed self-representation on behavior. Hum. Commun. Res. 2007, 33, 271–290. [Google Scholar] [CrossRef] [Scilit]
- Yee, N.; Bailenson, J.N.; Ducheneaut, N. The Proteus effect: Implications of transformed digital self-representation on online and offline behavior. Commun. Res. 2009, 36, 285–312. [Google Scholar] [CrossRef] [Scilit]
- Banakou, D.; Hanumanthu, P.D.; Slater, M. Virtual embodiment of white people in a black virtual body leads to a sustained reduction in implicit racial bias. Front. Hum. Neurosci. 2016, 10, 601. [Google Scholar] [CrossRef] [Scilit]
- Ernst, M.O.; Bülthoff, H.H. Merging the senses into a robust percept. Trends Cogn. Sci. 2004, 8, 162–169. [Google Scholar] [CrossRef] [Scilit]
- Stein, B.E.; Stanford, T.R. Multisensory integration: Current issues from the perspective of the single neuron. Nat. Rev. Neurosci. 2008, 9, 255–266. [Google Scholar] [CrossRef] [Scilit]
- Spence, C.; Driver, J. (Eds.) Crossmodal Space and Crossmodal Attention; Oxford University Press: Oxford, UK, 2004. [Google Scholar]
- Calvert, G.A.; Spence, C.; Stein, B.E. (Eds.) The Handbook of Multisensory Processes; MIT Press: Cambridge, MA, USA, 2004. [Google Scholar]
- Deroy, O.; Spence, C.; Noppeney, U. Metacognition in multisensory perception. Trends Cogn. Sci. 2016, 20, 736–747. [Google Scholar] [CrossRef] [Scilit]
- Spence, C. Multisensory perception. In Oxford Research Encyclopedia of Psychology; Oxford University Press: Oxford, UK, 2020. [Google Scholar] [CrossRef] [Scilit]
- Bowman, D.A.; McMahan, R.P.; Ragan, E.D. Questioning naturalism in 3D user interfaces. Commun. ACM 2012, 55, 78–88. [Google Scholar] [CrossRef] [Scilit]
- Posner, M.I.; Petersen, S.E. The attention system of the human brain. Annu. Rev. Neurosci. 1990, 13, 25–42. [Google Scholar] [CrossRef] [PubMed]
- Wickens, C.D. Multiple resources and performance prediction. Theor. Issues Ergon. Sci. 2002, 3, 159–177. [Google Scholar] [CrossRef] [Scilit]
- Lawson, G.; Shaw, E.; Roper, T.; Nilsson, T.; Bajorunaite, L.; Batool, A. Immersive virtual worlds: Multi-sensory virtual environments for health and safety training. arXiv 2019, arXiv:1910.04697. [Google Scholar] [CrossRef] [Scilit]
- Fairclough, S.H.; Ewing, K.C. The effect of task demand and incentive on neurophysiological and cardiovascular markers of effort. Int. J. Psychophysiol. 2017, 119, 58–66. [Google Scholar] [CrossRef] [Scilit]
- Corbetta, M.; Shulman, G.L. Control of goal-directed and stimulus-driven attention in the brain. Nat. Rev. Neurosci. 2002, 3, 201–215. [Google Scholar] [CrossRef] [Scilit]
- Parsons, T.D. Virtual Reality for Enhanced Ecological Validity and Experimental Control in the Clinical, Affective and Social Neurosciences. Front. Hum. Neurosci. 2015, 9, 660. [Google Scholar] [CrossRef] [Scilit]
- Wittmann, M. The inner experience of time. Philos. Trans. R. Soc. B Biol. Sci. 2009, 364, 1955–1967. [Google Scholar] [CrossRef] [Scilit]
- Block, R.A.; Hancock, P.A.; Zakay, D. How cognitive load affects duration judgments: A meta-analytic review. Acta Psychol. 2010, 134, 330–343. [Google Scholar] [CrossRef] [Scilit]
- Schatzschneider, C.; Bruder, G.; Steinicke, F. Who turned the clock? Effects of manipulated time perception in virtual environments. In Proceedings of the ACM Symposium on Virtual Reality Software and Technology, Munich, Germany, 2–4 November 2016. [Google Scholar]
- Rockstroh, B.; Elbert, T.; Birbaumer, N.; Lutzenberger, W. Slow Cortical Potentials and Behavior, 2nd ed.; Urban & Schwarzenberg: Munich, Germany, 1990. [Google Scholar]
- Gruzelier, J.H. EEG-neurofeedback for optimising performance. I: A review of cognitive and affective outcome in healthy participants. Neurosci. Biobehav. Rev. 2014, 44, 124–141. [Google Scholar] [CrossRef] [Scilit]
- Thibault, R.T.; Lifshitz, M.; Raz, A. The self-regulating brain and neurofeedback: Experimental science and clinical promise. Cortex 2017, 74, 247–261. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Gehrke, L.; Koselevs, A.; Klug, M.; Gramann, K. Neuroadaptive haptics: A proof-of-concept comparing reinforcement learning from explicit ratings and neural signals for adaptive extended reality systems. Front. Virtual Real. 2025, 6, 1616442. [Google Scholar] [CrossRef] [Scilit]
- Wiederhold, B.K.; Riva, G. Virtual reality therapy: Emerging topics and future challenges. Cyberpsychol. Behav. Soc. Netw. 2019, 22, 3–6. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Merzenich, M.M.; Van Vleet, T.M.; Nahum, M. Brain plasticity-based therapeutics. Front. Hum. Neurosci. 2014, 8, 385. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Draganski, B.; Gaser, C.; Busch, V.; Schuierer, G.; Bogdahn, U.; May, A. Neuroplasticity: Changes in grey matter induced by training. Nature 2004, 427, 311–312. [Google Scholar] [CrossRef] [Scilit]
- Radianti, J.; Majchrzak, T.A.; Fromm, J.; Wohlgenannt, I. A systematic review of immersive virtual reality applications for higher education: Design elements, lessons learned, and research agenda. Comput. Educ. 2020, 147, 103778. [Google Scholar] [CrossRef] [Scilit]
- Dayan, E.; Cohen, L.G. Neuroplasticity subserving motor skill learning. Neuron 2011, 72, 443–454. [Google Scholar] [CrossRef] [Scilit]
- Benedetti, F. Placebo Effects: Understanding the Mechanisms in Health and Disease; Oxford University Press: Oxford, UK, 2008. [Google Scholar]
- Büchel, C.; Geuter, S.; Sprenger, C.; Eippert, F. Placebo analgesia: A predictive coding perspective. Neuron 2014, 81, 1223–1239. [Google Scholar] [CrossRef] [Scilit]
- Wager, T.D.; Atlas, L.Y. The neuroscience of placebo effects: Connecting context, learning and health. Nat. Rev. Neurosci. 2015, 16, 403–418. [Google Scholar] [CrossRef] [Scilit]
- Wiederhold, B.K.; Wiederhold, M.D. Virtual reality therapy for anxiety disorders: Advances in evaluation and treatment. Am. Psychol. Assoc. 2005, 162, 1772. [Google Scholar] [CrossRef] [Scilit]
- Ulrich, R.S. View through a window may influence recovery from surgery. Science 1984, 224, 420–421. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kaplan, S. The restorative benefits of nature: Toward an integrative framework. J. Environ. Psychol. 1995, 15, 169–182. [Google Scholar] [CrossRef] [Scilit]
- Browning, M.H.E.M.; Mimnaugh, K.J.; van Riper, C.J.; Laurent, H.K.; LaValle, S.M. Can simulated nature support mental health? Comparing short, single-doses of 360-degree nature videos in virtual reality with the outdoors. Front. Psychol. 2019, 10, 2667. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yin, J.; Zhu, S.; MacNaughton, P.; Allen, J.G.; Spengler, J.D. Physiological and cognitive performance responses to indoor biophilic environments. Build. Environ. 2018, 132, 255–262. [Google Scholar] [CrossRef] [Scilit]
- Goyal, M.; Singh, S.; Sibinga, E.M.S.; Gould, N.F.; Rowland-Seymour, A.; Sharma, R.; Berger, Z.; Sleicher, D.; Maron, D.D.; Shihab, H.M.; et al. Meditation programs for psychological stress and well-being: A systematic review and meta-analysis. JAMA Intern. Med. 2014, 174, 357–368. [Google Scholar] [CrossRef] [Scilit]
- Tang, Y.-Y.; Hölzel, B.K.; Posner, M.I. The neuroscience of mindfulness meditation. Nat. Rev. Neurosci. 2015, 16, 213–225. [Google Scholar] [CrossRef] [Scilit]
- Navarro-Haro, M.V.; Modrego-Alarcón, M.; Hoffman, H.G.; López-Montoyo, A.; Navarro-Gil, M.; Montero-Marin, J.; García-Campayo, J. Evaluation of a mindfulness-based intervention with and without virtual reality distraction for chronic pain patients. Front. Psychol. 2017, 8, 1480. [Google Scholar] [CrossRef] [Scilit]
- Kiecolt-Glaser, J.K.; McGuire, L.; Robles, T.F.; Glaser, R. Emotions, morbidity, and mortality: New perspectives from psychoneuroimmunology. Annu. Rev. Psychol. 2002, 53, 83–107. [Google Scholar] [CrossRef] [Scilit]
- Segerstrom, S.C.; Miller, G.E. Psychological stress and the human immune system: A meta-analytic study of 30 years of inquiry. Psychol. Bull. 2004, 130, 601–630. [Google Scholar] [CrossRef] [Scilit]
- Rizzolatti, G.; Craighero, L. The mirror-neuron system. Annu. Rev. Neurosci. 2004, 27, 169–192. [Google Scholar] [CrossRef] [Scilit]
- Buccino, G.; Riggio, L. The role of the mirror neuron system in motor learning. Kinesiology 2006, 38, 5–15. [Google Scholar]
- Iacoboni, M. Mirroring People: The Science of Empathy and How We Connect with Others; Farrar, Straus and Giroux: New York, NY, USA, 2009. [Google Scholar]
- Hasson, U.; Ghazanfar, A.A.; Galantucci, B.; Garrod, S.; Keysers, C. Brain-to-brain coupling: A mechanism for creating and sharing a social world. Trends Cogn. Sci. 2012, 16, 114–121. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Dumas, G.; Nadel, J.; Soussignan, R.; Martinerie, J.; Garnero, L. Inter-brain synchronization during social interaction. PLoS ONE 2010, 5, e12166. [Google Scholar] [CrossRef] [Scilit]
- Konvalinka, I.; Roepstorff, A. The two-brain approach: How can mutually interacting brains teach us something about social interaction? Front. Hum. Neurosci. 2012, 6, 215. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Novembre, G.; Keller, P.E. A conceptual review on action–perception coupling in the musician’s brain: What is it good for? Front. Hum. Neurosci. 2014, 8, 603. [Google Scholar] [CrossRef] [Scilit]
- Angelaki, D.E.; Cullen, K.E. Vestibular system: The many facets of a multimodal sense. Annu. Rev. Neurosci. 2008, 31, 125–150. [Google Scholar] [CrossRef] [Scilit]
- Weech, S.; Kenny, S.; Barnett-Cowan, M. Presence and cybersickness in virtual reality are negatively related: A review. Front. Psychol. 2019, 10, 158. [Google Scholar] [CrossRef] [Scilit]
- Hoffman, H.G.; Patterson, D.R.; Carrougher, G.J.; Sharar, S.R. Effectiveness of virtual reality-based pain control with multiple treatments. Clin. J. Pain 2001, 17, 229–235. [Google Scholar] [CrossRef] [Scilit]
- Hoffman, H.G.; Richards, T.L.; Coda, B.; Bills, A.R.; Blough, D.; Richards, A.L.; Sharar, S.R. Modulation of thermal pain-related brain activity with virtual reality: Evidence from fMRI. Neuroreport 2004, 15, 1245–1248. [Google Scholar] [CrossRef] [Scilit]
- Wiederhold, B.K.; Gao, K.; Kong, L.; Wiederhold, M.D. Mobile virtual reality as a distraction intervention for pediatric pain and anxiety. Cyberpsychol. Behav. Soc. Netw. 2014, 17, 477–482. [Google Scholar] [CrossRef] [Scilit]
- Pourmand, A.; Davis, S.; Lee, D.; Barber, S.; Sikka, N. Emerging Utility of Virtual Reality as a Multidisciplinary Tool in Clinical Medicine. Games Health J. 2017, 6, 263–270. [Google Scholar] [CrossRef] [Scilit]
- Shadmehr, R.; Krakauer, J.W. A computational neuroanatomy for motor control. Exp. Brain Res. 2008, 185, 359–381. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Shadmehr, R.; Smith, M.A.; Krakauer, J.W. Error correction, sensory prediction, and adaptation in motor control. Annu. Rev. Neurosci. 2010, 33, 89–108. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Clark, A.; Chalmers, D. The extended mind. Analysis 1998, 58, 7–19. [Google Scholar] [CrossRef]
- Maravita, A.; Iriki, A. Tools for the body (schema). Trends Cogn. Sci. 2004, 8, 79–86. [Google Scholar] [CrossRef] [Scilit]
- Cardinali, L.; Frassinetti, F.; Brozzoli, C.; Urquizar, C.; Roy, A.C.; Farnè, A. Tool-use induces morphological updating of the body schema. Curr. Biol. 2009, 19, R478–R479. [Google Scholar] [CrossRef] [Scilit]
- Bowman, D.A.; Kruijff, E.; LaViola, J.J.; Poupyrev, I. 3D User Interfaces: Theory and Practice; Addison-Wesley: Boston, MA, USA, 2004. [Google Scholar]
- Ventsislavova, P.; Castro, C.; Crundall, D.; García-Fernández, P. Differences in hazard prediction ability between risky and non-risky drivers. Accid. Anal. Prev. 2021, 150, 105916. [Google Scholar] [CrossRef] [Scilit]
- Ware, C. Information Visualization: Perception for Design, 3rd ed.; Morgan Kaufmann: Burlington, MA, USA, 2012. [Google Scholar]
- Tao, F.; Zhang, H.; Liu, A.; Nee, A.Y.C. Digital twin in industry: State-of-the-art. IEEE Trans. Ind. Inform. 2019, 15, 2405–2415. [Google Scholar] [CrossRef] [Scilit]
- Skarbez, R.; Brooks, F.P.; Whitton, M.C. Immersive analytics: Theory and research agenda. Front. Robot. AI 2019, 6, 82. [Google Scholar] [CrossRef] [Scilit]
- Wolpert, D.M.; Flanagan, J.R. Motor prediction. Curr. Biol. 2001, 11, R729–R732. [Google Scholar] [CrossRef] [Scilit]
- Friston, K. The free-energy principle: A unified brain theory? Nat. Rev. Neurosci. 2010, 11, 127–138. [Google Scholar] [CrossRef] [Scilit]
- Clark, A. Whatever next? Predictive brains, situated agents, and the future of cognitive science. Behav. Brain Sci. 2013, 36, 181–204. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Castro, C.; Salazar-Frías, D.; Szot, A.C.; Laffarga, L.; Muela, I.; Rodríguez-Bailón, M.; García-Fernández, P.; Eisman, E.; Chica, A. Using the orienting hazard prediction test to assess fitness-to-drive: Data from stroke survivors. Appl. Cogn. Psychol. 2025, 39, e70076. [Google Scholar] [CrossRef] [Scilit]
- Mehrabian, A.; Russell, J.A. An Approach to Environmental Psychology; MIT Press: Cambridge, MA, USA, 1974. [Google Scholar]
- Russell, J.A. Core affect and the psychological construction of emotion. Psychol. Rev. 2003, 110, 145–172. [Google Scholar] [CrossRef] [PubMed]
- Riva, G.; Mantovani, F.; Capideville, C.S.; Preziosa, A.; Morganti, F.; Villani, D.; Gaggioli, A.; Botella, C.; Alcañiz, M. Affective interactions using virtual reality: The link between presence and emotions. Cyberpsychol. Behav. 2007, 10, 45–56. [Google Scholar] [CrossRef] [Scilit]
- Greene, J.D.; Sommerville, R.B.; Nystrom, L.E.; Darley, J.M.; Cohen, J.D. An fMRI investigation of emotional engagement in moral judgment. Science 2001, 293, 2105–2108. [Google Scholar] [CrossRef] [Scilit]
- Batson, C.D. These things called empathy: Eight related but distinct phenomena. In The Social Neuroscience of Empathy; Decety, J., Ickes, W., Eds.; MIT Press: Cambridge, MA, USA, 2009; pp. 3–15. [Google Scholar]
- Herrera, F.; Bailenson, J.; Weisz, E.; Ogle, E.; Zaki, J. Building long-term empathy: A large-scale comparison of traditional and virtual reality perspective-taking. PLoS ONE 2018, 13, e0204494. [Google Scholar] [CrossRef] [Scilit]
- Vinciarelli, A.; Pantic, M.; Bourlard, H. Social signal processing: Survey of an emerging domain. Image Vis. Comput. 2009, 27, 1743–1759. [Google Scholar] [CrossRef] [Scilit]
- Miller, M.R.; Jun, H.; Herrera, F.; Yu Villa, J.; Welch, G.; Bailenson, J.N. Social interaction in augmented reality. PLoS ONE 2019, 14, e0216290. [Google Scholar] [CrossRef] [Scilit]
- Kitchin, R. The Data Revolution: Big Data, Open Data, Data Infrastructures and Their Consequences; SAGE Publications: London, UK, 2014. [Google Scholar]
- Di Flumeri, G.; Aricò, P.; Borghini, G.; Colosimo, A.; Pozzi, S.; Babiloni, F. Brain–computer interface-based adaptive automation to prevent out-of-the-loop phenomenon in air traffic controllers dealing with highly automated systems. Front. Hum. Neurosci. 2019, 13, 296. [Google Scholar] [CrossRef] [Scilit]
- Flavell, J.H. Metacognition and cognitive monitoring: A new area of cognitive–developmental inquiry. Am. Psychol. 1979, 34, 906–911. [Google Scholar] [CrossRef]
- Nelson, T.O.; Narens, L. Metamemory: A theoretical framework and new findings. In The Psychology of Learning and Motivation; Bower, G.H., Ed.; Academic Press: New York, NY, USA, 1990; Volume 26, pp. 125–173. [Google Scholar] [CrossRef] [Scilit]
- Castro, C.; Ventsislavova, P.; García-Fernández, P.; Crundall, D. Risky decision making and hazard prediction are negatively related and could be assessed independently using driving footage. Psychol. Res. Behav. Manag. 2021, 14, 857–870. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kaber, D.B.; Endsley, M.R. The effects of level of automation and adaptive automation on human performance, situation awareness, and workload in a dynamic control task. Theor. Issues Ergon. Sci. 2004, 5, 113–153. [Google Scholar] [CrossRef] [Scilit]
- Amershi, S.; Weld, D.; Vorvoreanu, M.; Fourney, A.; Nushi, B.; Collisson, P.; Suh, J.; Iqbal, S.; Bennett, P.N.; Inkpen, K.; et al. Guidelines for human–AI interaction. In Proceedings of the 2019 CHI Conference on Human Factors in Computing Systems, Glasgow Scotland, UK, 4–9 May 2019; pp. 1–13. [Google Scholar] [CrossRef] [Scilit]
- Boksem, M.A.S.; Tops, M. Mental fatigue: Costs and benefits. Brain Res. Rev. 2008, 59, 125–139. [Google Scholar] [CrossRef] [Scilit]
- Caldwell, J.; Caldwell, J.L. Fatigue in Aviation: A Guide to Staying Awake at the Stick, 2nd ed.; Routledge: Oxfordshire, UK, 2016. [Google Scholar] [CrossRef] [Scilit]
- Ericsson, K.A. The influence of experience and deliberate practice on the development of superior expert performance. In The Cambridge Handbook of Expertise and Expert Performance; Ericsson, K.A., Charness, N., Feltovich, P.J., Hoffman, R.R., Eds.; Cambridge University Press: Cambridge, UK, 2006; pp. 683–703. [Google Scholar]
- Johnson-Glenberg, M.C. Immersive VR and Education: Embodied Design Principles that Include Gesture and Hand Controls. Front. Robot. AI 2018, 5, 81. [Google Scholar] [CrossRef] [Scilit]
- Csikszentmihalyi, M. Flow: The Psychology of Optimal Experience; Harper & Row: New York, NY, USA, 1990. [Google Scholar]
- Jackson, S.A.; Marsh, H.W. Development and validation of a scale to measure optimal experience: The Flow State Scale. J. Sport Exerc. Psychol. 1996, 18, 17–35. [Google Scholar] [CrossRef] [Scilit]
- Schacter, D.L.; Addis, D.R.; Buckner, R.L. Remembering the past to imagine the future: The prospective brain. Nat. Rev. Neurosci. 2007, 8, 657–661. [Google Scholar] [CrossRef] [Scilit]
- Suddendorf, T.; Corballis, M.C. The evolution of foresight: What is mental time travel, and is it unique to humans? Behav. Brain Sci. 2007, 30, 299–313. [Google Scholar] [CrossRef] [Scilit]
- Salvucci, D.D.; Taatgen, N.A. The Multitasking Mind; Oxford University Press: Oxford, UK, 2008. [Google Scholar]
- Norman, D.A. The Design of Everyday Things; Doubleday: New York, NY, USA, 1990. [Google Scholar]
- Bradshaw, J.M.; Hoffman, R.R.; Woods, D.D.; Johnson, M.; Feltovich, P.J. The seven deadly myths of “autonomous systems”. IEEE Intell. Syst. 2013, 28, 54–61. [Google Scholar] [CrossRef] [Scilit]
- Dautenhahn, K. Socially intelligent robots: Dimensions of human–robot interaction. Philos. Trans. R. Soc. B Biol. Sci. 2007, 362, 679–704. [Google Scholar] [CrossRef] [Scilit]
- Hershfield, H.E.; Goldstein, D.G.; Sharpe, W.F.; Fox, J.; Yeykelis, L.; Carstensen, L.L.; Bailenson, J.N. Increasing saving behavior through age-progressed renderings of the future self. J. Mark. Res. 2011, 48, S23–S37. [Google Scholar] [CrossRef] [Scilit]
- Schön, D.A. The Reflective Practitioner: How Professionals Think in Action; Basic Books: New York, NY, USA, 1983. [Google Scholar]
- Arksey, H.; O’Malley, L. Scoping studies: Towards a methodological framework. Int. J. Soc. Res. Methodol. 2005, 8, 19–32. [Google Scholar] [CrossRef] [Scilit]
- Peters, M.D.J.; Marnie, C.; Tricco, A.C.; Pollock, D.; Munn, Z.; Alexander, L.; McInerney, P.; Godfrey, C.M.; Khalil, H. Updated methodological guidance for the conduct of scoping reviews. JBI Evid. Synth. 2020, 18, 2119–2126. [Google Scholar] [CrossRef] [Scilit]
- International Telecommunication Union. Global Digital Cooperation Report: AI and XR Governance Frameworks; International Telecommunication Union: Geneva, Switzerland, 2024. [Google Scholar]



| Concept | Definition | Primary System Focus | Role of XR | Role of AI | Implications for Human Capability | Typical Application Contexts |
|---|---|---|---|---|---|---|
| Extended Reality (XR) | Umbrella term covering virtual, augmented, and mixed reality technologies that modify or extend perception through immersive interfaces. | Interface technology | Primary component | Optional | Enhances perception and interaction | Simulation, visualization, training, immersive environments |
| Artificial Intelligence (AI) | Computational systems capable of performing tasks that normally require human intelligence, including perception, prediction, and decision support. | Algorithmic intelligence | Optional | Primary component | Supports cognition and decision making | Automation, decision support, adaptive systems, data analysis |
| Augmented Cognition | Human–technology systems designed to enhance cognitive performance through adaptive interfaces, physiological sensing, and feedback. | Human performance optimization | Optional | Optional | Improves attention, workload regulation, and learning | Neuroergonomics, adaptive interfaces, training systems |
| Cyber-Physical Systems (CPS) | Integrated systems combining computation, sensing, and physical processes operating in real time and distributed environments. | System-level integration | Optional | Optional | Coordinates human, machine, and environment | Smart cities, robotics, industrial control, infrastructure monitoring |
| Digital Twins | Virtual representations of physical systems used for monitoring, simulation, and decision support in real time. | Operational modeling | Often used | Often used | Supports understanding and control of complex systems | Industry, infrastructure, healthcare, smart cities |
| Extended Intelligence (XI) | Closed-loop integration of immersive XR interfaces and adaptive AI within cyber-physical environments, enabling psychobiological mechanisms (TAXI) that converge into capability-level outcomes (XI-CAP). | Human–XR–AI capability systems | Core interface layer | Core adaptive layer | May extend or constrain human capability depending on design | Teleoperation, digital twins, immersive collaboration, training, smart-city systems |
| Framework Level | Description | Role in the XI Framework | Typical Methods | Example Constructs/Outputs |
|---|---|---|---|---|
| Conceptual scope of Extended Intelligence (XI) | Definition of XR–AI systems as closed-loop human–technology environments operating in phygital and cyber-physical contexts. | Establishes theoretical scope and distinguishes XI from XR, AI, and augmented cognition. | Conceptual analysis, literature synthesis, framework definition | XR–AI environments, digital twins, immersive collaboration, cyber-physical systems |
| TAXI mechanisms (mechanism level) | Taxonomy of psychobiological efficacy mechanisms through which XR–AI interaction may influence perception, cognition, physiology, affect, and action. | Provides empirically grounded building blocks for capability analysis. | Experimental XR studies, neuroscience, human factors, neuroergonomics | Presence, embodiment, multisensory integration, workload regulation, trust calibration, fatigue dynamics |
| Mechanism grouping | Organization of mechanisms into functional clusters reflecting perceptual, physiological, sensorimotor, social, and cognitive processes. | Improves interpretability and supports compositional analysis of mechanisms. | Taxonomy synthesis, cross-domain comparison | Experiential, regulatory, sensorimotor, affective, cognitive, and distributed-interaction mechanisms |
| XI-CAP capability patterns | Higher-level performance outcomes emerging from combinations of TAXI mechanisms under realistic interaction conditions. | Translates mechanism-level evidence into capability-level hypotheses. | Conceptual synthesis, neuroergonomics, motor learning, human–AI interaction | Remote super-dexterity, distributed cognition, adaptive workload regulation, collective coordination |
| Empirical validation layer | Experimental testing of whether proposed capability patterns can be produced, stabilized, and reproduced under realistic conditions. | Defines research agenda and validation requirements. | Controlled experiments, longitudinal studies, multi-user studies, physiological measurement | Mechanism stability, fatigue effects, trust calibration, long-duration usability |
| Design and deployment guidelines | Translation of validated capability patterns into system design principles and operational constraints. | Supports safe and reliable XI system development. | Human factors engineering, usability testing, field trials | Interface design, AI adaptation rules, workload limits, safety constraints |
| Operational XI systems | Real-world XR–AI environments in which validated mechanisms and capabilities are used under realistic conditions. | Target domain of the framework. | Deployment studies, cyber-physical evaluation, large-scale testing | Digital twins, teleoperation, smart cities, medical collaboration, immersive training |
| XR Mechanism (as reported by Spiegel et al. [47] | XR Domain Classification (based on Spiegel et al. [47] | TAXI Mechanism (ID and Label) | Mapping Interpretation within TAXI Framework |
|---|---|---|---|
| Presence/immersion | XR neuropsychological and biological mechanisms of action | M1 Presence and Immersion | Direct adoption |
| Virtual embodiment | XR neuropsychological and biological mechanisms of action | M2 Virtual Embodiment | Direct adoption |
| Proteus effect | XR neuropsychological and biological mechanisms of action | M3 Proteus Effect | Direct adoption |
| Multisensory input in XR | XR neuropsychological and biological mechanisms of action | M4 Multisensory Integration | Direct adoption (generalized label) |
| Distraction/spotlight of attention | XR neuropsychological and biological mechanisms of action | M5 Distraction and Attentional Modulation | Direct adoption (expanded label) |
| Alterations of time perception | XR neuropsychological and biological mechanisms of action | M6 Altered Time Perception | Direct adoption |
| Biofeedback in XR | XR neuropsychological and biological mechanisms of action | M7 Biofeedback/Neurofeedback Integration | Direct adoption (closed-loop framing) |
| Physiological effects of XR | XR neuropsychological and biological mechanisms of action | M8 Physiological Regulation | Direct adoption (refined scope) |
| Neurobiological effects of XR | XR neuropsychological and biological mechanisms of action | M9 Neurobiological Modulation | Direct adoption (refined scope) |
| Placebo/sham effects | XR neuropsychological and biological mechanisms of action | M10 Placebo and Expectancy Effects | Direct adoption |
| Biophilia/nature environments | XR neuropsychological and biological mechanisms of action | M11 Biophilia and Nature-Based Effects | Direct adoption |
| Meditation effects of XR | XR neuropsychological and biological mechanisms of action | M12 Meditation and Mindfulness Effects | Direct adoption |
| Immunological effects of XR | XR neuropsychological and biological mechanisms of action | M13 Immunological Effects | Direct adoption (evidence maturity noted) |
| Vestibular/motion cue effects | Ethics, safety, privacy, and adverse effects of MXR | M16 Vestibular Engagement and Motion Cue Integration | Cross-category adoption |
| Cybersickness/simulator sickness | Ethics, safety, privacy, and adverse effects of MXR | M17 Sensory Conflict and Cybersickness Dynamics | Cross-category adoption |
| No. | XI Capability | Short Definition | Supporting TAXI Mechanisms | Supporting Literature |
|---|---|---|---|---|
| C1 | Remote Super-Dexterity | Capacity to perform fine, high-precision actions remotely with near co-located control fidelity | M1, M2, M4, M19, M20, M22 | [72,97,106,130,160,167] |
| C2 | Scale Transcendence Action (Micro–Macro) | Capacity to perceive and act effectively across non-human spatial scales | M1, M2, M4, M21, M36 | [18,73,162,164] |
| C3 | Accelerated Skill Acquisition and Transfer | Accelerated acquisition of skills under immersive conditions | M6, M9, M14, M19, M33, M40, M42 | [120,128,130,144,158,188,199] |
| C4 | Continuous Cognitive Load Regulation | Potential for dynamic regulation of attention, arousal, and workload during complex tasks | M5, M7, M8, M12, M31, M32, M34, M39 | [113,114,122,141,185,186,190] |
| C5 | Resilient Long-Duration Performance | Maintenance of performance quality under prolonged use | M6, M8, M10, M11, M12, M31, M32, M40 | [120,128,133,136,137,187] |
| C6 | Pain-Tolerant Task Execution | Potential to maintain task performance despite discomfort or minor pain | M5, M10, M18 | [133,134,152] |
| C7 | Collective Distributed Cognition | Hypothesized capacity for coordinated group-level cognition and action across distributed agents | M15, M26, M28, M30 | [69,75,147,148] |
| C8 | Identity-Based Performance Modulation | Potential for modulation of behavior and performance through role-based embodiment | M2, M3, M23, M24 | [100,103,172] |
| C9 | Moral and Perspective Expansion | Potential for enhanced ethical reasoning and empathic perspective-taking through immersive experience | M25, M26 | [175,176] |
| C10 | Human–AI Co-Regulated Action | Capacity for joint regulation of perception, decision-making, and action between humans and AI systems | M27, M28, M29, M30, M32, M39, M20 | [75,85,159,182,185] |
| C11 | Embodied Tool and Machine Assimilation | Potential for integration of tools or machines into the user’s sense of agency and control | M2, M19, M20, M22 | [78,130,160,167] |
| C12 | Multi-Space Supervision and Agent-Orchestrated Attention | Hypothesized capacity for distributed awareness across multiple environments supported by agent-driven prioritization and delegation | M37, M38, M39, M28, M30, M32 | [75,114,185,194,196] |
| Priority Theme | TAXI/XI-CAP Linkages | Evaluation Context/Benchmarks | Supporting Literature |
|---|---|---|---|
| R1 Mechanism validity under operational load | TAXI: M1–M12, M30–M32; XI-CAP: C1, C4, C5, C10, C11 | Control rooms; industrial pilots; shift-work simulations; long-duration exposure (4–8 h); high-stakes tasks; time-on-task stability | [86,116,186] |
| R2 Multi-mechanism synergy and interference | TAXI: M1–M9, M14–M15, M23–M34, M37–M39; XI-CAP: C1–C6, C10, C12 | Factorial XR experiments; multimodal cue combinations; controlled interaction studies; synergy/interference mapping under prolonged use | [76,86] |
| R3 Workload shaping via adaptive XR–AI | TAXI: M5, M27, M29–M30, M32, M39; XI-CAP: C4, C5, C10, C12 | Adaptive interfaces; real-time workload sensing; adaptive pacing experiments; performance and error benchmarking under dynamic UI conditions | [75,86,185] |
| R4 Fatigue and vigilance sustainment | TAXI: M6, M8, M31–M32, M34; XI-CAP: C5 | Extended monitoring; vigilance decrement curves; endurance simulations (8–12 h); cumulative fatigue tracking | [120,186,187] |
| R5 Trust calibration and safe AI reliance | TAXI: M28–M30, M39; XI-CAP: C10, C12 | AI reliability manipulation experiments; override drills; human–AI teaming benchmarks; longitudinal trust drift monitoring | [75,85,185] |
| R6 Distributed cognition and shared situation awareness | TAXI: M15, M26–M28; XI-CAP: C7 | Multi-team simulations; digital twin operations; collaborative mission rehearsal; coordination stability over time | [69,147,150] |
| R7 Proxy agents and distributed supervisory intelligence | TAXI: M37–M39, M30–M32; XI-CAP: C12 (and C10) | Multi-asset monitoring; anomaly response testing; escalation and triage evaluation; false-alarm fatigue | [75,185] |
| R8 Embodiment and agency extension boundaries | TAXI: M2, M16–M17, M19–M20, M22; XI-CAP: C1, C11 | Teleoperation latency trials; cybersickness testing; agency attribution; long-duration headset use; multi-day tolerance | [78,154] |
| R9 Training transfer and reflective replay learning | TAXI: M14, M19, M33, M40, M42; XI-CAP: C3 | Certification benchmarks; simulator-to-real transfer; replay-based debriefing; retention tests; stress-condition transfer | [129,130,144] |
| R10 Affective priming and ethical performance optimization | TAXI: M23, M10, M8 (opt. M24); XI-CAP: C8, C9 | Nudging experiments; affect modulation safety testing; stress–performance trade-offs; longitudinal affect drift | [132,172] |
| R11 Social presence and empathy stability | TAXI: M25–M26 (opt. M23–M24); XI-CAP: C9 | Longitudinal empathy studies; behavioral follow-up; adverse outcome monitoring; emotional fatigue | [175,176] |
| R12 Temporal simulation and counterfactual planning | TAXI: M35, M42, M10; XI-CAP: cross-cutting (C10, C12) | Disaster rehearsal; foresight experiments; counterfactual reasoning evaluation; planning accuracy stability | [192,193] |
| R13 High-dimensional abstraction and systems insight | TAXI: M36, M27, M32 (opt. M39); XI-CAP: C2 | Visualization benchmarks; interpretability tasks; systems debugging; delayed insight recall | [164] |
| R14 Longitudinal adaptation and unintended consequences | TAXI: M9, M27, M30–M32, M40; XI-CAP: C3, C5, C10 | Longitudinal pilots; cognitive drift tracking; wellbeing baselines; multi-week XR–AI exposure; dependency indicators | [127,128,186] |
| R15 Governance, ethics, safety, and interoperability | Cross-cutting (all mechanisms; C1–C12) | Standards mapping; regulatory readiness; accessibility validation; auditability; sustainability assessment | [49,51,53,202] |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Tromp, J.; El Makrini, I.; Trógolo, M.; Muñoz, M.A.; Sánchez-Barrerra, M.B.; Pacheco, J.P.; Castro, C. Designing Extended Intelligence: A Taxonomy of Psychobiological Effects of XR–AI Systems for Human Capability Augmentation. Virtual Worlds 2026, 5, 18. https://doi.org/10.3390/virtualworlds5020018
Tromp J, El Makrini I, Trógolo M, Muñoz MA, Sánchez-Barrerra MB, Pacheco JP, Castro C. Designing Extended Intelligence: A Taxonomy of Psychobiological Effects of XR–AI Systems for Human Capability Augmentation. Virtual Worlds. 2026; 5(2):18. https://doi.org/10.3390/virtualworlds5020018
Chicago/Turabian StyleTromp, Jolanda, Ilias El Makrini, Mario Trógolo, Miguel A. Muñoz, Maria B. Sánchez-Barrerra, Jose Pech Pacheco, and Cándida Castro. 2026. "Designing Extended Intelligence: A Taxonomy of Psychobiological Effects of XR–AI Systems for Human Capability Augmentation" Virtual Worlds 5, no. 2: 18. https://doi.org/10.3390/virtualworlds5020018
APA StyleTromp, J., El Makrini, I., Trógolo, M., Muñoz, M. A., Sánchez-Barrerra, M. B., Pacheco, J. P., & Castro, C. (2026). Designing Extended Intelligence: A Taxonomy of Psychobiological Effects of XR–AI Systems for Human Capability Augmentation. Virtual Worlds, 5(2), 18. https://doi.org/10.3390/virtualworlds5020018