


Abstract
The joint configuration design of aerospace equipment requires a comprehensive balance of multiple factors, yet the process is often complex and time-consuming. Moreover, the Function–Behavior–Structure (FBS) conceptual design model lacks specificity for aerospace joint design. To address these issues, a Function–Performance–Structure (FPS)-based design method for joint configuration is proposed. Service performance is introduced as a bridge to map functional requirements to structural characteristics, thereby establishing a complete FPS conceptual design framework. Based on this, a conceptual design methodology for aerospace joint configurations is developed using typical aircraft structures as the research object. To verify the effectiveness and reliability of the method, a typical joint configuration is selected for instance validation. By integrating conceptual modeling with structural joint design, the proposed method offers a novel approach for aerospace joint configuration design, providing a theoretical foundation to enhance both the innovation capability and engineering value of aerospace equipment design.
1. Introduction
Aerospace equipment primarily includes aircraft, aero engines, and aviation equipment and systems. Currently, the industry is undergoing profound transformation, driven by trends such as intelligence, greenness, autonomy, innovation in new materials, and adjustments in global supply chains. These developments place new demands on structural joints: lightweight and ecofriendly designs require novel joint solutions compatible with advanced materials; autonomous operation and intelligent maintenance call for more reliable and easily inspectable connections; and globalized supply chains highlight the need for standardized and adaptable joint designs. As a critical part of aerospace equipment, joint structures play a key role in ensuring structural stability and functional integrity. However, studies have shown that approximately 75–80% of fatigue failures [1] occur in these joint areas, making joint quality crucial to the reliability and safety of the equipment.
Common joint methods include bolting, welding, riveting, and bonding. Among these methods, bolting and riveting are the most widely used. In this paper, the term “fastener joint configuration” is defined as the combination of these two types of fasteners and various connected components, under specific assembly conditions. To meet the demands of complex service conditions, such configurations must not only ensure sufficient mechanical performance, but also withstand extreme conditions such as high temperatures and corrosion [2]. In some cases, components at special positions must transfer forces or torque while accommodating relative motion with adjacent parts, thereby requiring higher physical performance. Currently, typical fastener joint configurations are generally classified into fixed joints (e.g., surface joints, cylindrical joints, I-beam joints) and movable joints (e.g., pin joints, hinge joints). The design process for aerospace equipment joints is complex, multidisciplinary, and held to extremely high standards. However, the lack of universal design specifications for these joints significantly affects the overall design cycle. Additionally, constraints such as the geometry of connected parts, surrounding structures, and application scenarios often lead to limited internal space, suboptimal aerodynamic layouts, increased structural weight, and difficulties in assembly and manufacturing [3].
Existing design methods, such as Design for Assembly (DFA) and Design for Manufacturing and Assembly (DFMA) [4], can assist decision-making to some extent. However, they primarily focus on mechanical performance evaluation and lack targeted guidance for system-level fastener joint configuration design. As a result, design processes often rely heavily on manual work and iterative verification, which leads to high design intensity, prolonged cycles [5], high redundancy, and low optimization efficiency. A universal, systematic, and reusable conceptual design method is urgently needed.
Facing this challenge, there is an urgent need to establish a more systematic and adaptable conceptual design framework for this field. The conceptual design [6,7,8] has a decisive impact on product quality and life cycle cost. According to studies, decisions made during this stage can affect up to 85% of the total lifecycle cost and over 70% of product quality [9]. The Function–Behavior–Structure (FBS) model, a classical framework for conceptual design, was proposed by Gero in 1990 [10]. It decomposes design problems into three layers and builds hierarchical mappings to guide the design evolution from abstract to concrete. It provides a mechanism for mapping between design intentions and product structures [11]. Over time, the FBS model has been extended in various ways to adapt to specific domains [12]. For instance, Umeda [13] introduced the Function–Behavior–State (FBS2) model with a “state” variable, which incorporated physical features and supported both the analysis and synthesis stages of functional design through computer-based tools. Wang et al. [14] proposed the Constraint-based Function–Behavior–Structure (CFBS) model using constraint aggregation to support reverse design, which established a human–computer interaction approach for product appearance design. Qin et al. [15] introduced the Reuse-oriented Function–Behavior–Structure–Evolution (RFBSE) model to enhance knowledge representation and evolution, enabling the capture and reuse of design knowledge and experience. Deng [16] developed the Function–Environment–Behavior–Structure (FEBS) model by adding environmental parameters for green design, and further defined a reasoning process, in which design schemes can be generated through reverse-path inference. These variants have achieved practical results across different fields, demonstrating the model’s extensibility and generality.
Although the FBS model has been widely applied in conceptual product design [17,18,19,20,21,22], and its extended forms (such as the CFBS, RFBSE, and FEBS models) have achieved certain successes in constraint handling, knowledge reuse, and green design, these studies have primarily focused on their respective specific application fields and have not yet provided effective solutions to the performance-driven issues in aerospace fastener joint configuration design. The core of this research challenge lies in the unique definition dilemma of the “behavior” layer in aerospace connection configuration design. In traditional product design paradigms, the behavior layer typically serves as a mediating bridge between function and structure. However, in the design of fastening joints, greater emphasis is placed on performance-oriented factors such as material property matching, adaptability to service environments, and feasibility of assembly processes. These factors are difficult to accurately represent using the traditional “behavior” concept. To address this, this study innovatively proposes replacing the “behavior” layer with a “performance” layer, thereby establishing a Function–Performance–Structure (FPS) design model. This model overcomes the limitations of traditional frameworks and more precisely reflects the essential needs of joint configuration design. Based on this, we have developed a comprehensive FPS-guided joint configuration conceptual design method, and its efficiency and feasibility are systematically validated through typical aircraft joint case studies.
The structure of the paper is organized as follows: Section 2 establishes the FPS conceptual design model and outlines the corresponding FPS-based design process. In Section 3, the FPS model is applied to aircraft structures, where an FPS-based mapping model for aircraft fastener joint configuration design is developed. Additionally, a configuration library that guides the output of the functional layer results and selection rule tables that provides the basis for FP mapping are introduced to provide a detailed description of the design process. Section 4 validates the proposed method’s feasibility and effectiveness through a typical aircraft fastener joint case study. Finally, Section 5 presents the conclusion.
2. Development of the FPS Model and Conceptual Design Process
2.1. FPS Model
The FBS conceptual design model is renowned for its broad generality and has been widely applied across various product design domains. However, due to this very generality, the FBS model often lacks operational specificity in practical design tasks, making its direct application challenging. Therefore, a practical approach to enhancing the effectiveness of conceptual design is to adapt the FBS framework and develop more concrete design models that are tailored to the specific needs of individual product designs.
In general design contexts, the “Behavior” in the FBS model is generally defined as the responses or manifestations of a design object under specific conditions, including motion patterns, structural deformation, and so on. However, for aerospace joint configurations, these mechanistic responses are relatively predictable and provide limited abstraction or guidance for conceptual design. In contrast, “Performance” [23,24] refers to measurable service-oriented indicators, such as fatigue life, durability, and long-term reliability. Although these indicators depend on mechanical responses, they reflect higher-level engineering objectives that directly determine design feasibility. At the same time, Performance-Based Structural Design (PBSD) [25] has been widely adopted in both aerospace and civil engineering, providing quantifiable performance criteria and guiding engineering decision-making. Therefore, introducing “Performance” as a bridge between function and structure enhances the relevance of the conceptual model to aerospace joint design and helps ensure long-term reliability while satisfying functional requirements, thus addressing the limitations of the FBS model in joint configuration design.
In the design process of aerospace fastener joint configurations, user requirements generally fall into two categories: functional requirements and specific parameter requirements. The former describes the functional characteristics the joint configuration must achieve and serves as the input to the FPS model during the conceptual design phase. The latter includes explicit geometric, mechanical, or boundary parameters that support parametric design and the establishment of structural parameter sets in the structural layer. As the conceptual design progresses, a workpiece module representing the output of structural layer is ultimately obtained. Thus, in the new conceptual design model, functional requirements, as input, are denoted as “R”, while the workpiece module, as output, is denoted as “W”.
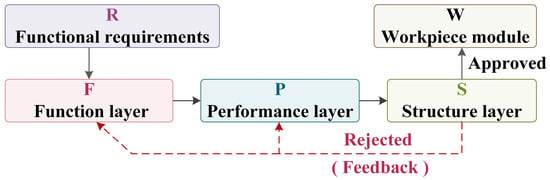
Based on this reasoning and drawing from the three-layer logic of the FBS model, an FPS conceptual design process model is developed, as illustrated in Figure 1. In this model, functional requirements represents the starting point of design activities; function (F) is defined the design objectives, describing the functional characteristics the joint configuration must fulfill; performance (P) specifies the design constraints, detailing the boundary conditions necessary for the structure; structure (S) refers to the configuration form that satisfies both the functional and the boundary conditions derived from performance; and the workpiece module (W) is the representation of the structure, serving as the final design outcome.
Figure 1.
FPS mapping model.
The FPS model defines a structured mapping mechanism encompassing three key relationships: function–performance (FP), performance–structure (PS), and function–structure (FS). In the FP mapping, the function, derived from user requirements, is constrained and guided by relevant performance parameters. These performance elements act as intermediaries, bridging the gap between functional intent and structural realization. The PS mapping is bidirectional: structural forms are derived in response to boundary constraints, and the resulting structures are then assessed against the same performance criteria. Discrepancies identified during evaluation feed back into the design process, enabling refinement of the structural forms to satisfy the performance objectives. When a structural solution fails to satisfy the intended functional requirements, the FS mapping mechanism enables an iterative feedback process. This process may involve modifying the structural elements in relation to their associated functions, and if necessary, adjusting the functional requirements themselves. The updated requirements then guide a new selection or refinement of structural solutions to ensure that the final design meets both functional and performance objectives.
2.2. Construction of the FPS-Based Design Process
In the field of aerospace equipment fastener joint structure design, it is necessary to systematically analyze the design prerequisites and key influencing factors based on existing typical joint solutions. By introducing the mapping logic of the FPS model, hierarchical analysis can be carried out from three dimensions: function (F), performance (P), and structure (S). Each dimension can be further subdivided into sublayers: subfunctions (Fm), subperformances (Pm), and substructures (Sm). Among these, the subitems of the function and performance layers can be further decomposed into elemental contents (Fmn, Pmn). This multi-level classification approach enables systematic organization of design elements, thereby constructing a complete FPS model framework suitable for aerospace equipment joint configuration. Based on this framework, by collecting and organizing existing joint configuration cases, a structured design knowledge base can be established, providing comprehensive information support for the subsequent conceptual design phase.
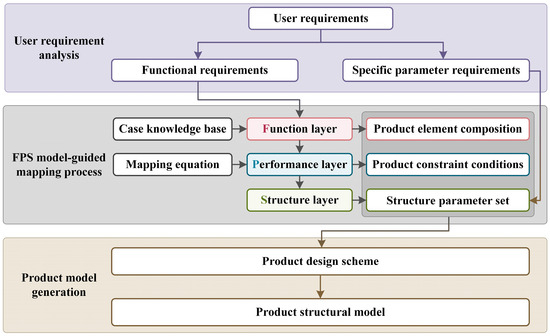
Accordingly, an FPS based conceptual design process is illustrated in Figure 2, specifically aimed at the design of fastener joint configurations for aerospace equipment. The process begins with analyzing user requirements to identify relevant functional elements. These elements, combined with the case knowledge library, form an initial element composition of the workpiece module. These functional elements are then translated into performance constraints, which define the product constraint conditions required to meet functional intent. Guided by these constraint conditions, appropriate substructures are selected and configured to form a structural description, which is then combined with the specific parameter requirements to generate a structure parameter set. Finally, by integrating the outputs across all three layers, a feasible conceptual design scheme is generated, which is further refined through computational analysis and verification. Once the design passes all performance checks, the final structural model is established.
Figure 2.
FPS-based product design process model.
In practical applications, the case knowledge library may contain multiple types of schematic diagrams that satisfy the same functional requirement. This leads to various possible combinations in the output of function layer, ultimately resulting in multiple candidate product design schemes. In such cases, a comparative evaluation considering adaptability, feasibility, and other relevant metrics is required to identify the optimal solution.
Given the complexity and multiplicity of factors in fastener joint configuration design, particularly in the FP mapping, parameter mapping equations [26,27,28] are adopted to formally represent the causal relationships among design layers. Taking the FP mapping as an example, let the input set be and the output set . Each performance element corresponds to a mapping equation , forming an equation set φ:
where fi is a mapping equation, capturing the relationship between selected functional elements in input set I and the corresponding performance elements in the i-th subperfomance. These mapping equations are typically defined using structured rule tables or expert knowledge bases, which are primarily derived from domain-specific design textbooks and the relevant literature. The rule tables and knowledge bases can be periodically updated or supplemented to incorporate new design practices or insights.
Ultimately, the complete equation set φ yields a comprehensive set of performance layer outputs, enabling a traceable mapping pathway from the function layer to structure layer. The output set O obtained through the equation set φ is as follows:
When necessary, this descriptive approach can also be applied to the PS mapping process. Moreover, when multiple solutions satisfy the same functional requirements, two resolution strategies are proposed. Specifically, characteristics of alternative solutions are recorded in the structured rule tables, enabling designers to perform screening according to project-specific constraints or design objectives. Alternatively, several candidate solutions can be preserved and further developed into distinct design schemes, followed by comparative analysis and verification to determine the optimal configuration scheme. This dual-strategy mechanism ensures that the mapping process not only provides traceable relationships but also remains flexible in handling uncertainties in design choices.
3. FPS-Based Design Method for Aircraft Fastener Joint Configurations
In the design of fastener joint configurations for aerospace equipment, the connected parts and their structural forms are diverse. In cases involving complex spatial relationships or high strength requirements, it is often necessary to introduce intermediate components or ribs within it. Therefore, the conceptual design phase primarily focuses on structural model design of both fasteners and intermediate components. To better align the FPS model framework with the practical requirements of fastener joint configuration design, this section applies it to aircraft structures, and a corresponding FPS configuration mapping model is constructed.
3.1. FPS Mapping Model for Aircraft Fastener Joint Configurations
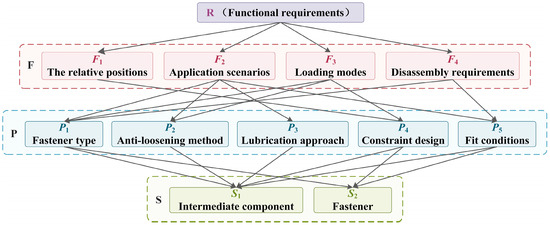
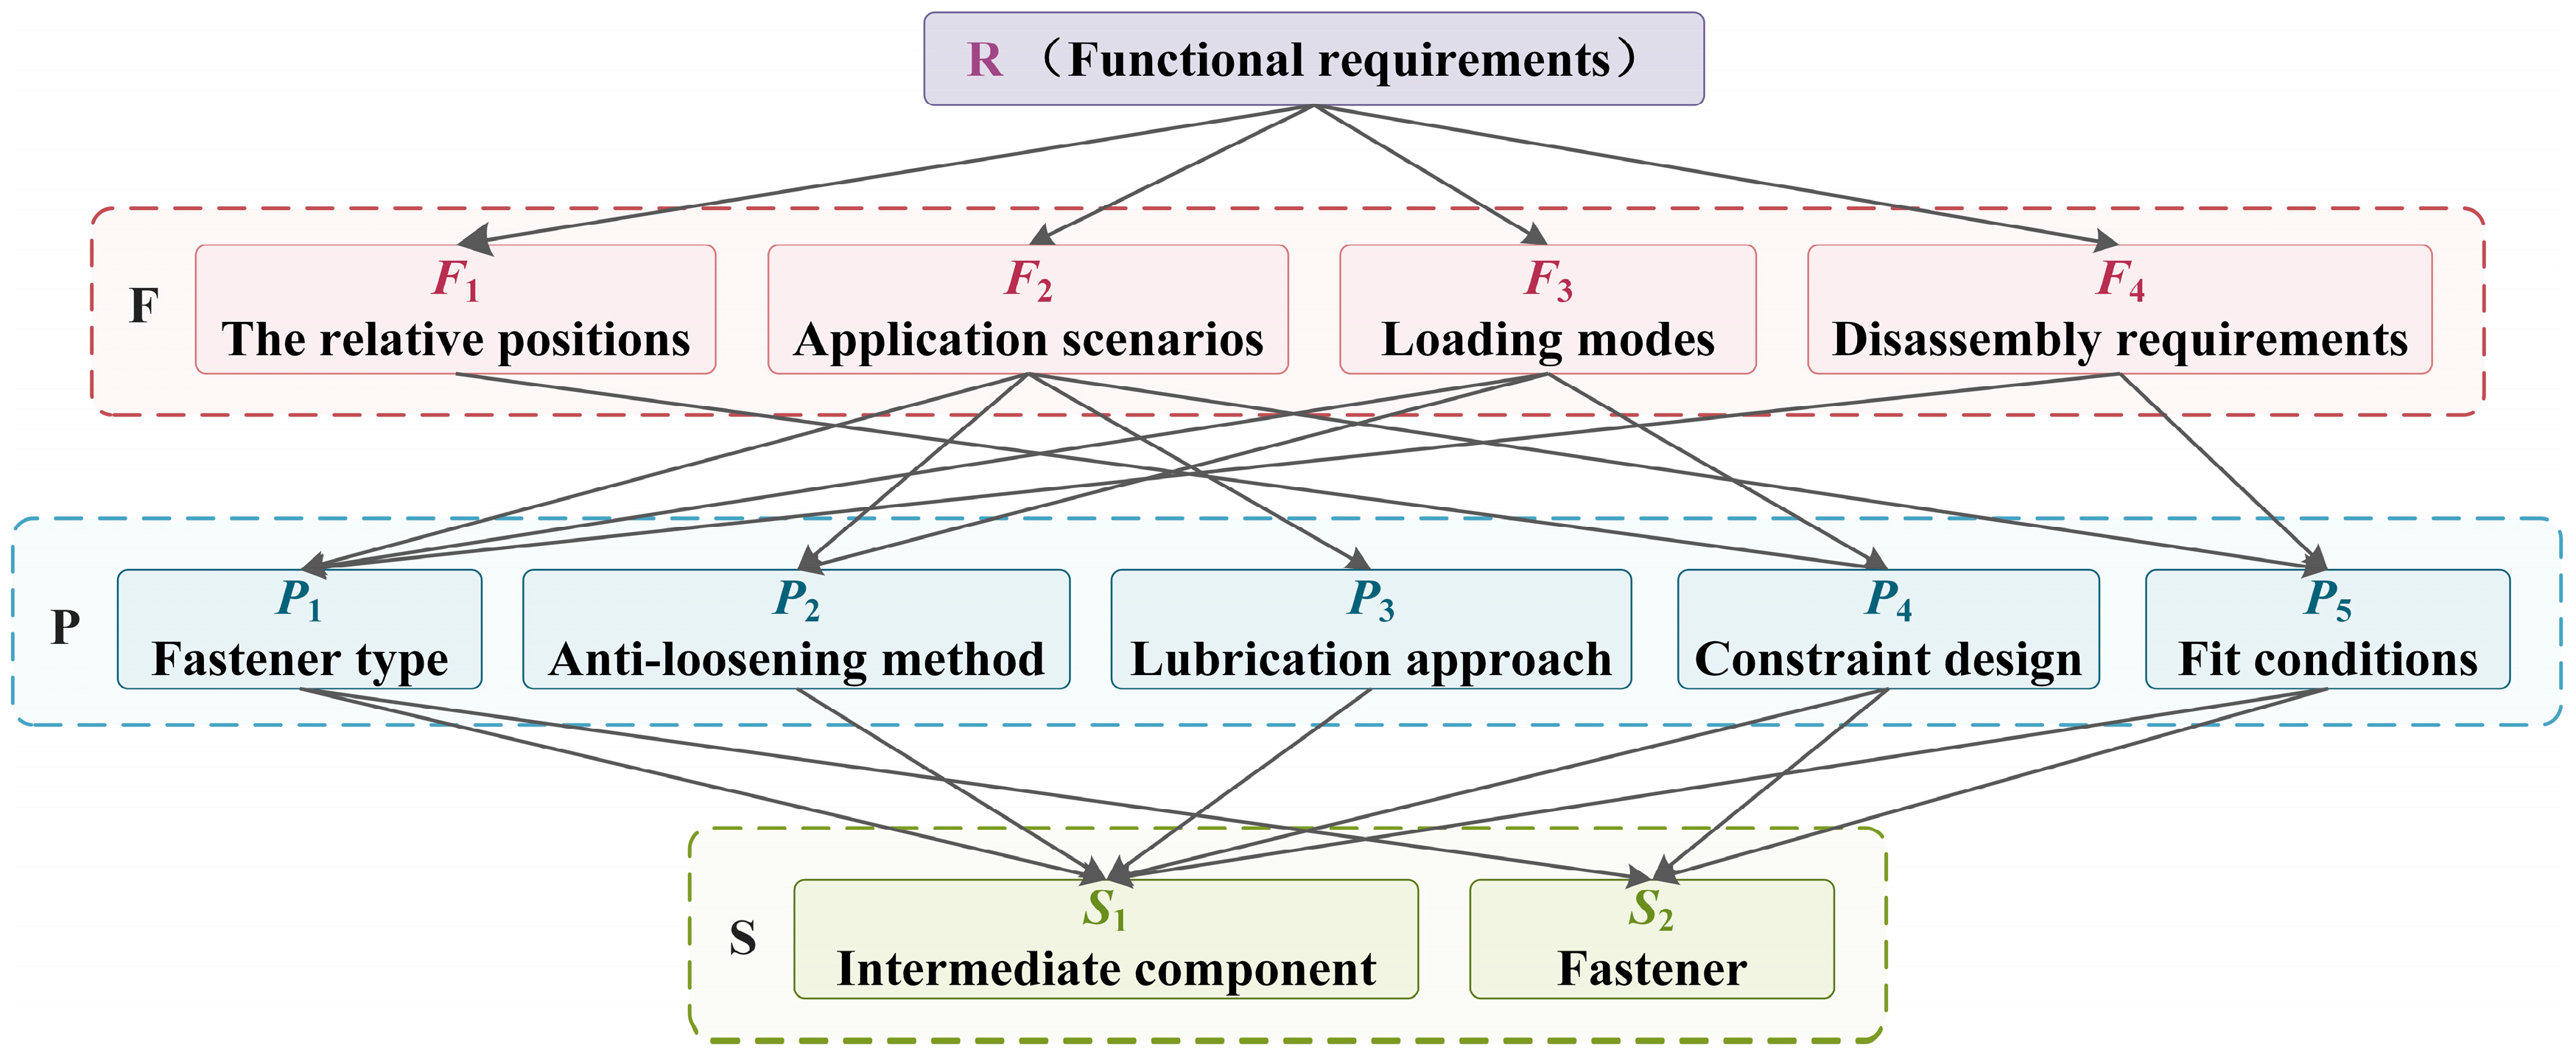
Using aircraft structures as the research object, a detailed classification and summary of fastener joint configurations was made, through extensive offline investigations, design books, and a literature review. The similarities and differences among various joint configurations, along with their underlying causes, were analyzed, and the logical steps required for joint configuration design were derived. The design of fastener joint configurations must first consider key factors, such as the relative positions of the connected components, application scenarios, loading modes, and disassembly requirements. These design-driving factors are categorized as subfunctions under the function layer.
From these subfunctions, a series of constraints can be derived, such as fastener type, anti-loosening method, lubrication approach, constraint design, and fit conditions, which are categorized as subperformances within the performance layer. Notably, both the function and performance layers directly or indirectly determine the elements of the structure layer. Accordingly, the structure layer is further divided into two substructures: intermediate component and fastener. Figure 3 presents the FPS-based mapping model for aircraft fastener joint configurations, in which elements of the three layers were denoted by codes, with clearly defined mapping relationships.
Figure 3.
The FPS-based mapping model for aircraft fastener joint configurations (F: function layer; Fm: subfunctions; P: performance layer; Pm: subperformances; S: structure layer; and Sm: substructures).
The function layer is defined as the source of connection requirements, encompassing structural relations, working environments, and operational demands that the joint must satisfy. The performance layer is located between the functional layer and the structural layer, providing executable design constraints for functions. With reference to relevant connection design manuals and aerospace engineering cases [29,30,31,32,33], the function and performance layers are further refined. The corresponding function elements and performance elements within each subfunction and subperformance are clearly specified, as summarized in Table 1 and Table 2, respectively, to ensure broad coverage of typical engineering design scenarios.
Table 1.
Function elements content.
Table 2.
Performance elements content.
The structure layer provides the final physical design output. Guided by the defined performance parameters, it configures the substructures and describes them using parametric form. The substructures include the intermediate component S1 and the fastener S2, and their conceptual descriptions are provided from a feature perspective, as shown in Table 3.
Table 3.
Fastener joint configuration structure parameter set.
3.2. FPS Design Process for Aircraft Fastener Joint Configurations
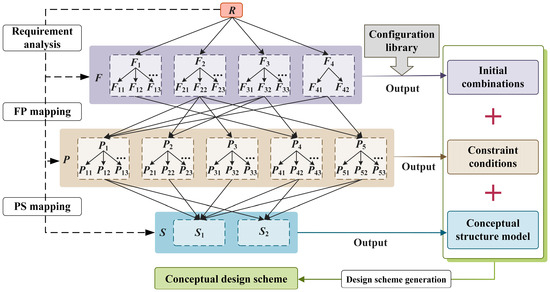
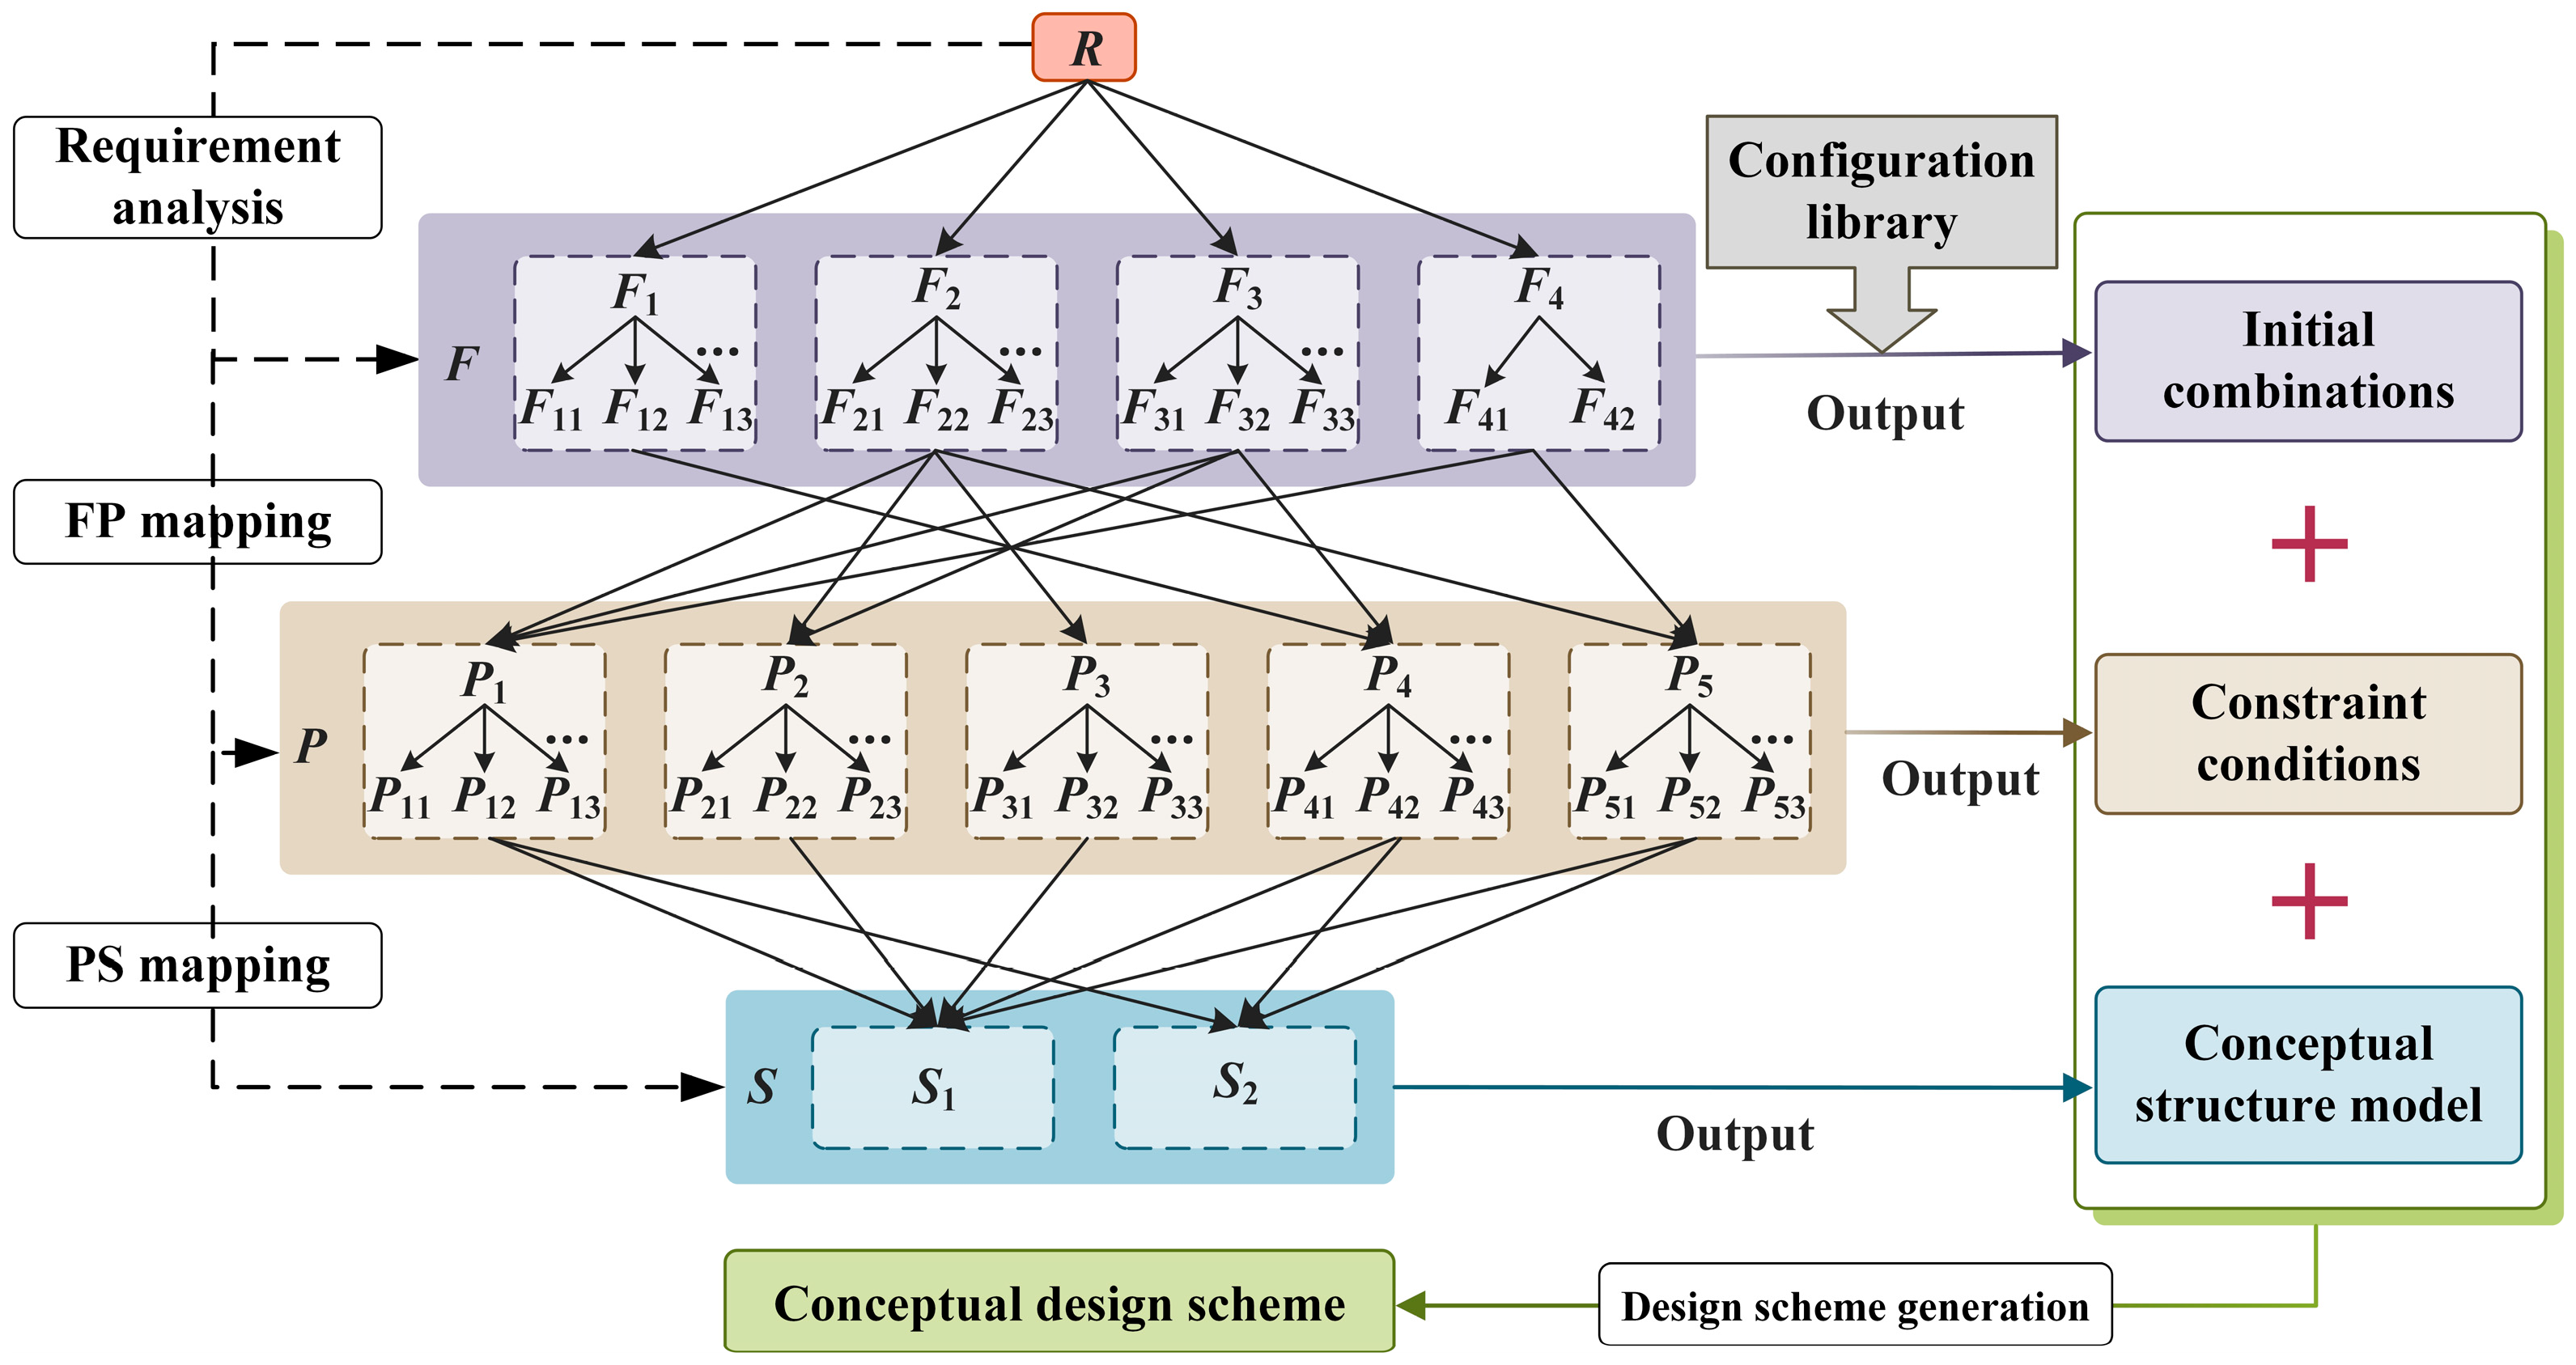
To introduce the FPS model into the design process of fastener joint configurations in aircraft structures, a practical design process is proposed, as illustrated in Figure 4. A configuration library is introduced to support decision-making, particularly under the default design scenario, in which the user must define a joint for a specific location within the aircraft structure. This methodology can also be adapted for other aerospace equipment through appropriate model and database extensions.
Figure 4.
FPS-based conceptual design workflow for aircraft fastener joint configurations (R: functional requirements; F: function layer; Fm: subfunctions; Fmn: functional element; P: performance layer; Pm: subperformances; Pmn: performance element; S: structure layer; and Sm: substructures).
3.2.1. Requirement Analysis
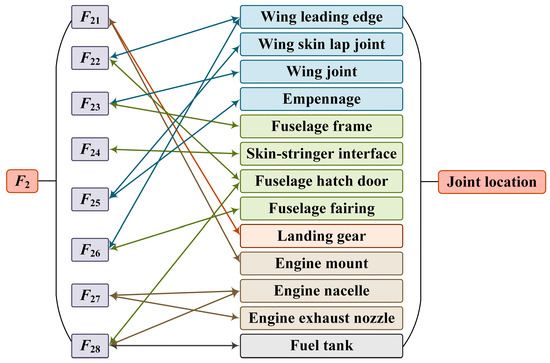
The process begins with requirement analysis, where the functional elements in the function layer are identified. Specifically, during the analysis of application scenarios, users often provide the specific joint location. A reference mapping between the joint location and scenario type, as shown in Figure 5, helps in selecting the appropriate subfunctions F2. Next, guided by the configuration library and informed by subfunctions F1 and the provided joint location, an initial set of configuration combinations is screened. Each combination includes a connection form diagram and a fastener layout diagram. Simultaneously, the functional elements F1n, F2n, F3n, and F4n identified in the function layer are used as input conditions for the performance layer.
Figure 5.
Mapping between joint location and scenario type (Fm: subfunctions and Fmn: functional element).
Based on studies of journals and books [29,30,31,32,33,34,35,36], as well as onsite investigations at numerous aircraft maintenance facilities and exhibitions, we decomposed and categorized publicly available existing aerospace equipment joint structures to establish the configuration library. The compilation process of the library is presented in detail in the Supplementary Material, where the structural schematics of each joint configuration were abstracted through analyses of existing engineering cases in combination with the construction of structural simulation models. To ensure engineering applicability and reliability, each connection type and layout pattern was cross-validated against engineering cases, technical manuals, and expert knowledge. Furthermore, the configuration library can be updated by periodically incorporating newly published design data or validated engineering cases.
The classification and summary of joint configurations are integrated to establish a comprehensive configuration library, which includes two key aspects: connection types and fastener layout patterns. Under the connection type category, fastener joint configurations are classified into three main groups: surface joints, tube joints, and motion joints, as shown in Table 4, Table 5 and Table 6. For surface joints (Table 4), they are further categorized based on the relative positioning of components into vertical (F11), parallel (F12), and annular types (F13). Additionally, configurations are differentiated by the requirement for intermediate components: either indirect (with intermediate parts) (Table 4a) or direct (without intermediate parts) (Table 4b). In the case of indirect configurations, the joint is further classified into ribbed or non-ribbed designs, depending on the structural load requirements. For tube joints (Table 5), configurations are divided into three types based on the connection state of the tube: fixed-to-surface, fixed-to-axis, and fixed-to-tube. These are further differentiated by the spatial relationship between the fixed components, including crossed (F14), parallel (F15), vertical (F16), and butt-jointed (F17) forms. Motion joints (Table 6) are classified into two categories: with intermediate components and without. According to the number of moving elements, they are further divided into two-bar (F18) and multi-bar (F19) configurations. For joints with intermediate components, three structural forms are identified based on how the intermediate component connects to the joined parts: front-side connection, inner-side connection, and outer-side connection. Each joint configuration type is accompanied by schematic illustrations and is named using letters or symbols based on its geometric shape, or descriptive terms are used for one-to-one correspondence according to the joint status. This ensures intuitive mapping and facilitates efficient retrieval and application when matched against the joint location provided by the user.
Table 4.
(a) Surface joints in the configuration selection library: indirect joint. (b) Surface joints in the configuration selection library: direct joint.
Table 5.
Tube joints in the configuration selection library.
Table 6.
Kinematic joints in the configuration selection library.
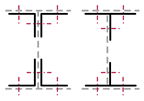
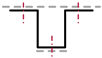
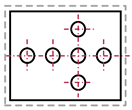
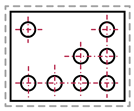
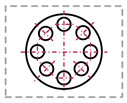
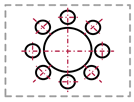
The fastener layout section includes both arrangement patterns and typical joint configuration layouts, as shown in Table 7 and Table 8. Each layout pattern can be flexibly combined with any of the defined connection types, allowing for adaptation to various structural requirements. In the schematic diagrams provided in these tables, solid lines represent the geometry of intermediate components, dashed lines indicate the profiles of connected components, and chain lines (alternating long and short dashes) represent the positions of fasteners (such as bolts or rivets).
Table 7.
Fastener arrangement patterns in the configuration selection library.
Table 8.
Typical joint layouts in the configuration selection library.
3.2.2. FP Mapping
Guided by the selected functional elements, corresponding subperformance parameters are identified. Drawing on references [29,30,31,32,33,34,35,36], selection rule tables for fastener joint configurations are established, as shown in Table 9, Table 10, Table 11, Table 12, Table 13, Table 14 and Table 15. These tables clearly define the constraint equations associated with each subperformance and consider the interdependencies among them to ensure consistency and engineering feasibility across the overall performance parameter set.
Table 9.
Selection rules for fastener types.
Table 10.
Selection rules for anti-loosening methods.
Table 11.
Selection rules for lubrication methods.
Table 12.
Fastener constraint design selection rules-force analysis.
Table 13.
Fastener constraint design selection rules for bolt and rivet design.
Table 14.
Fastener constraint design selection rules for fastener layout and intermediate component design.
Table 15.
Selection rules for fit conditions.
In accordance with aerospace design and fastening technology standards, the fastener type selection table (Table 9) further refines each performance element into subtypes. For each subtype, the key fastener characteristics and commonly used lubrication methods are specified to support rational fastener selection. In the tables for anti-loosening (Table 10) and lubrication methods (Table 11), in addition to describing the applicability of each performance element, the corresponding fastener types are also listed to provide clear guidance for the selection of both anti-loosening and lubrication methods. In the tables for fit conditions (Table 15), the application characteristics of the performance elements are clarified, and recommended tolerance grades are given for direct reference in subsequent engineering drawings. In the constraint design tables (Table 12, Table 13 and Table 14), based on established design guidelines, the calculation types associated with each performance element are summarized. Detailed design formulas and symbol definitions are provided, and each formula is numbered according to subtype hierarchy. The subtypes defined in these selection tables represent the final categorization of performance elements, forming the output of the performance layer and serving as input to the structure layer. For consistency, a unified numbering scheme of the form is adopted to identify subtypes and their hierarchical contents.
During the mapping process, functional elements from the function layer are sequentially substituted into the mapping functions of the performance sublayers . The selection is carried out in ascending order of n, yielding both the fastener performance outputs (fastener type, anti-loosening method, lubrication method, and fit condition) and the parameter design workflow, which consists of the specific design equations identified in the constraint design subperformance.
3.2.3. PS Mapping
The fastener properties and parameter design procedure, outputted from the performance layer, is further translated into a detailed characteristic description of substructure. Specifically, the fastener properties directly correspond to the fasteners (S1) in the structure layer. The design equations involved in the parameter design procedure are applied to the specific parameter requirements by the designer to calculate detailed structural dimensions, and the resulting values provide parameter descriptions for both the fasteners (S1) and the intermediate components (S2). Finally, these results, together with the parameters of the connected components contained in the specific requirements, are integrated to form a complete structural parameter set of the joint configuration, as shown in Table 16, which serves as the output of the structure layer. Here, since the structure layer contains only a limited number of substructures, it is not necessary to employ mapping functions to explicitly express the mapping process.
Table 16.
Structure parameter set of the designed fastener joint configuration.
The structural parameter set includes the basic geometric dimensions of the three key components in the joint configuration (connected components, intermediate components S1, and fasteners S2), as well as their specific parameter features (such as the loading conditions of the connected components, the rib dimensions of the intermediate components, and the layout parameters of the fasteners, etc.). This dataset supports downstream tasks including modeling, simulation, engineering drawing generation, and process implementation.
3.2.4. Design Scheme Generation
The outputs from all layers (including product elements, design constraints, and the structure parameter set) are integrated to generate one or more complete conceptual design schemes, as shown in Table 17. Considering that users typically specify two connected components, the key parameters of both components, as well as those of the joint interfaces between the connected components and the intermediate component, are listed in detail. In cases involving multiple feasible configurations, the structural composition and dimensional features of each joint configuration can be listed sequentially in the table to facilitate comparison and selection.
Table 17.
Conceptual design schemes of the designed fastener joint configuration: (a) connected components, (b)substructures.
In the final stage, the generated conceptual design schemes of the designed fastener joint configuration are subjected to evaluation based on performance. This involves general validation of fatigue life and reliability, as well as performance checks tailored to special application regions such as high-vibration, sealing, and aerodynamically sensitive areas. The specific verification formulas for performance criteria are provided in Table 18. If multiple candidate configurations pass the screening, the optimal scheme is determined by combining performance comparison with designer expertise. If none succeed, the process iterates: either by adjusting fastener layouts and reselecting the configuration diagram from the F layer, or modifying performance selections from the P layer, until a feasible design is achieved.
Table 18.
The performance indicator of the designed fastener joint configuration.
4. Case Study
4.1. Conceptual Design of the Joint Configuration Between the Mid-Fuselage Skin and the Annular Frame
To verify the applicability and effectiveness of the proposed FPS-based design method for aircraft fastener joint configurations, a typical connection scenario from the aircraft fuselage structure is selected.
The user requirement is defined as designing a detachable joint between the mid-fuselage skin and the annular frame to transfer aerodynamic loads and bending moments, while allowing for component replacement and maintenance. The detailed specifications of the connected components are as follows: The skin is made of 2024-T3 aluminum alloy, with a thickness of 3.5 mm. It is laid along the longitudinal direction of the fuselage and intersects perpendicularly with the annular frame. The overlap area is 300 mm in length and 40 mm in width. The main loading is the shearing force, . The frame is made of 7075-T6 aluminum alloy, with a thickness of 4 mm and an overlap width of 60 mm. It primarily carries bending moments.
Analyzing the user requirement reveals that the connection location and critical parameters are explicitly provided. According to the functional requirements, the following function elements from the F layer are extracted: F11, F23, F32, F3, and F41.
According to the joint location specified, initial combinations of configuration can be referenced from the configuration library. Substituting F11 and the skin–frame joint into Table 4 of the configuration library yields two preliminary applicable connection forms: the “L” shape and the “▲” shape. For fastener layout, according to Table 7 and Table 8, a dual-row linear pattern is selected to satisfy load transmission and compactness. Then, the set of function elements is mapped to the performance layer to derive the associated output set O:
where the output set for P4 is the following:
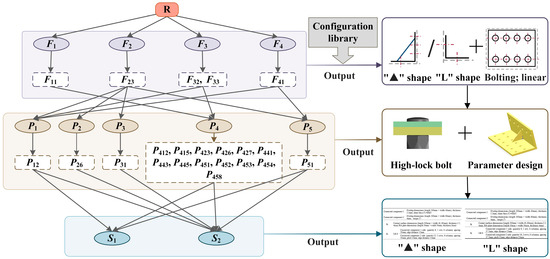
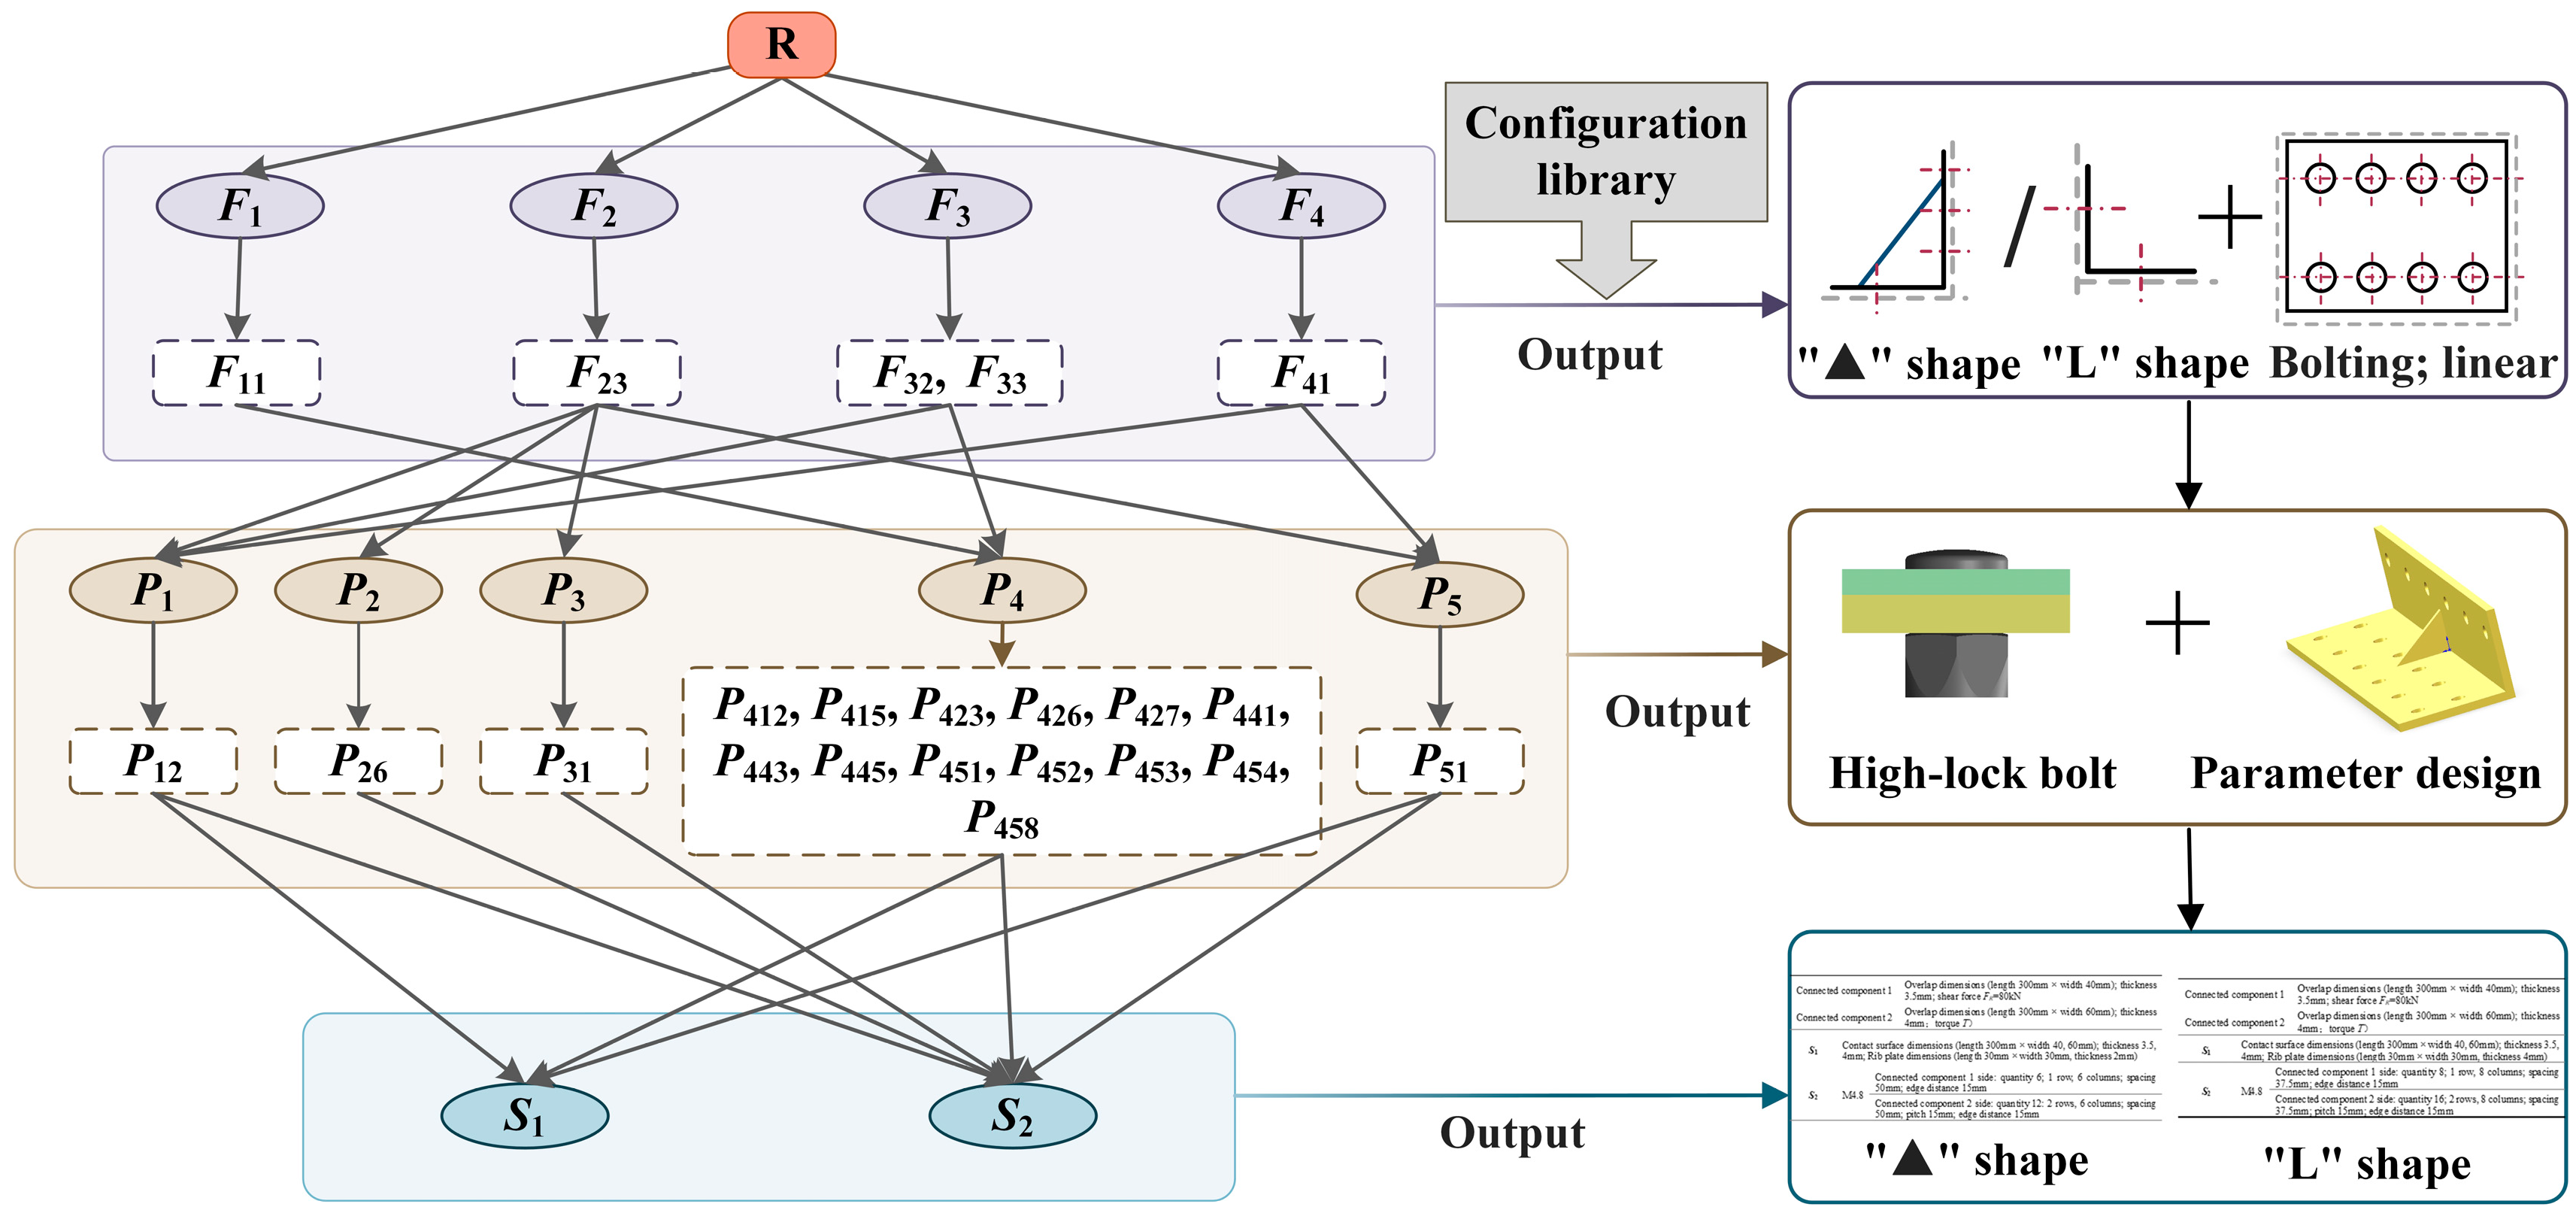
The output of the performance layer further constrains the parametric design of substructures S1 and S2 in the structure layer, resulting in a structure parameter set of the skin–frame joint configuration. At this point, the conceptual design flow for the skin–frame joint configuration is completed, as shown in Figure 6. By integrating the outputs from all three layers, two complete design schemes are ultimately generated, as illustrated in Table 19.
Figure 6.
Configuration design flow for the skin–frame joint configuration (R: functional requirements; F: function layer; Fm: subfunctions; Fmn: functional element; P: performance layer; Pm: subperformances; Pmn, Pmnz: performance elements; S: structure layer; and Sm: substructures).
Table 19.
Conceptual design schemes of the skin–frame fastener joint configuration: (a) connected components, (b)substructures.
According to Table 18, the two generated configurations were evaluated based on performance indicators. Numerical evaluation indicated that the “▲” shape joint configuration achieved a fatigue life of over 1.2 × 10⁵ load cycles and a reliability index of 0.995, thereby meeting the service life requirements. In contrast, the “L” shape joint configuration, although seemingly favorable under pure shear load sharing, showed a reduced fatigue life of only 6 × 10⁴ cycles and a reliability index of 0.96 due to secondary bending effects, failing to satisfy the design criteria. Based on both quantitative results and established design experience in fuselage joint structures, the “▲” shape joint configuration was finally adopted as the optimal joint design.
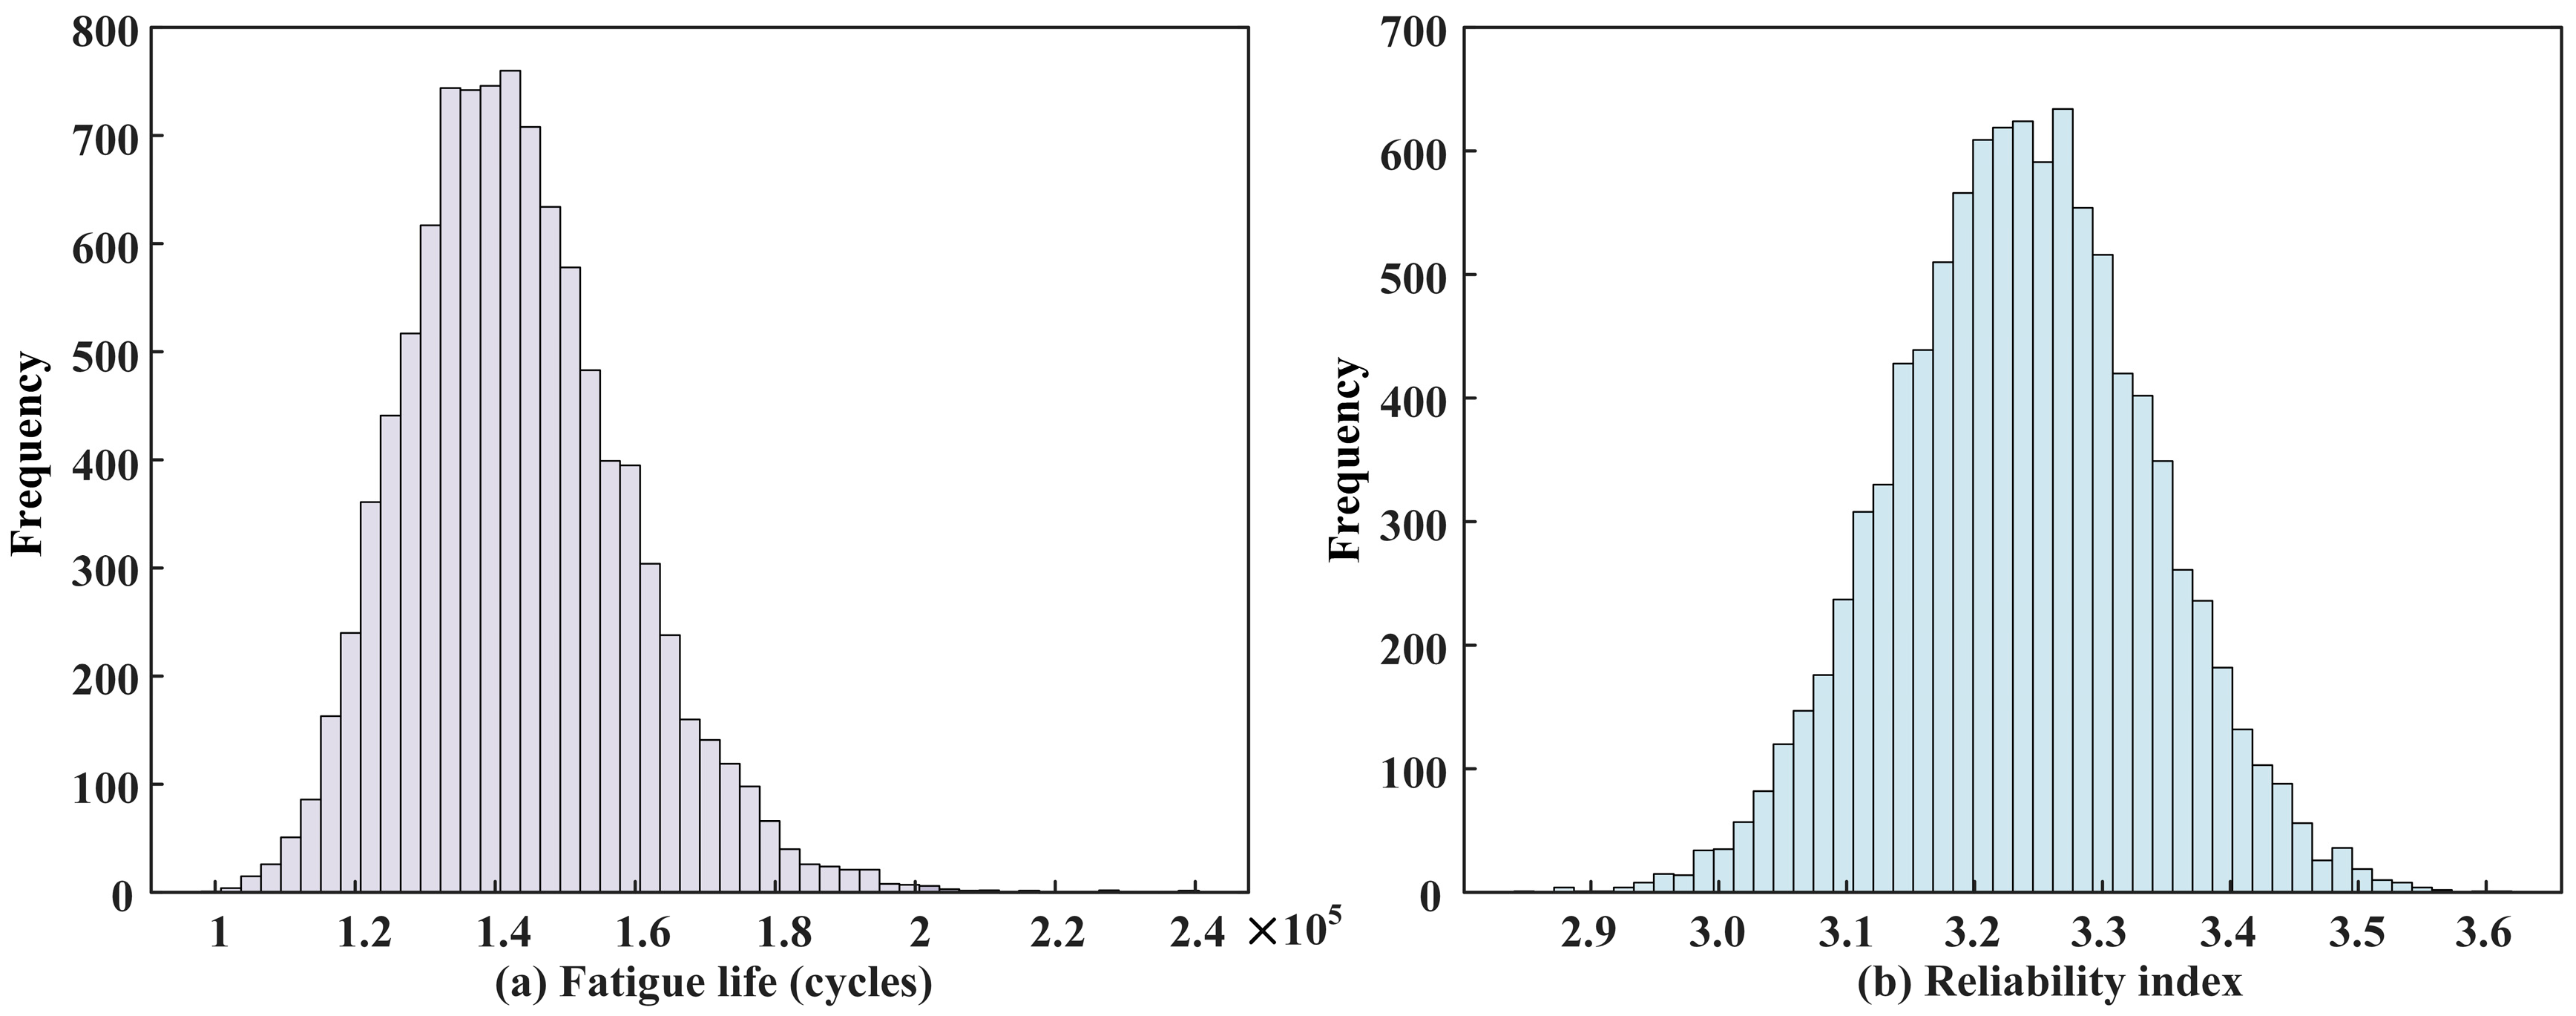
To further verify the robustness of the “▲” shape joint configuration under uncertainties, a Monte Carlo simulation was conducted considering variations in key parameters, including shear load, material strength, plate thickness, and fastener friction coefficient. Based on aerospace design experience, these parameters were assumed to follow normal or triangular distributions, as summarized in Table 20. Random samples were generated for each iteration, and the corresponding fatigue life and reliability index were calculated. The resulting distributions are presented in Figure 7.
Table 20.
Uncertainty parameters and their distributions.
Figure 7.
Monte Carlo simulation of (a) fatigue life and (b) reliability index.
As shown in Figure 7a, over 10,000 iterations, the fatigue life exhibited a mean of 1.43 × 10⁵ cycles, a standard deviation of 1.62 × 10⁴ cycles, and a 95% confidence interval of [1.16 × 105,1.79 × 105]. Figure 7b illustrates that the reliability index had a mean value of 3.236, a standard deviation of 0.100, and a 95% confidence interval of [3.040, 3.431]. These results indicate that the selected joint configuration maintains sufficient applicability and reliability under realistic variations in loading and material properties, providing a robust basis for the final design.
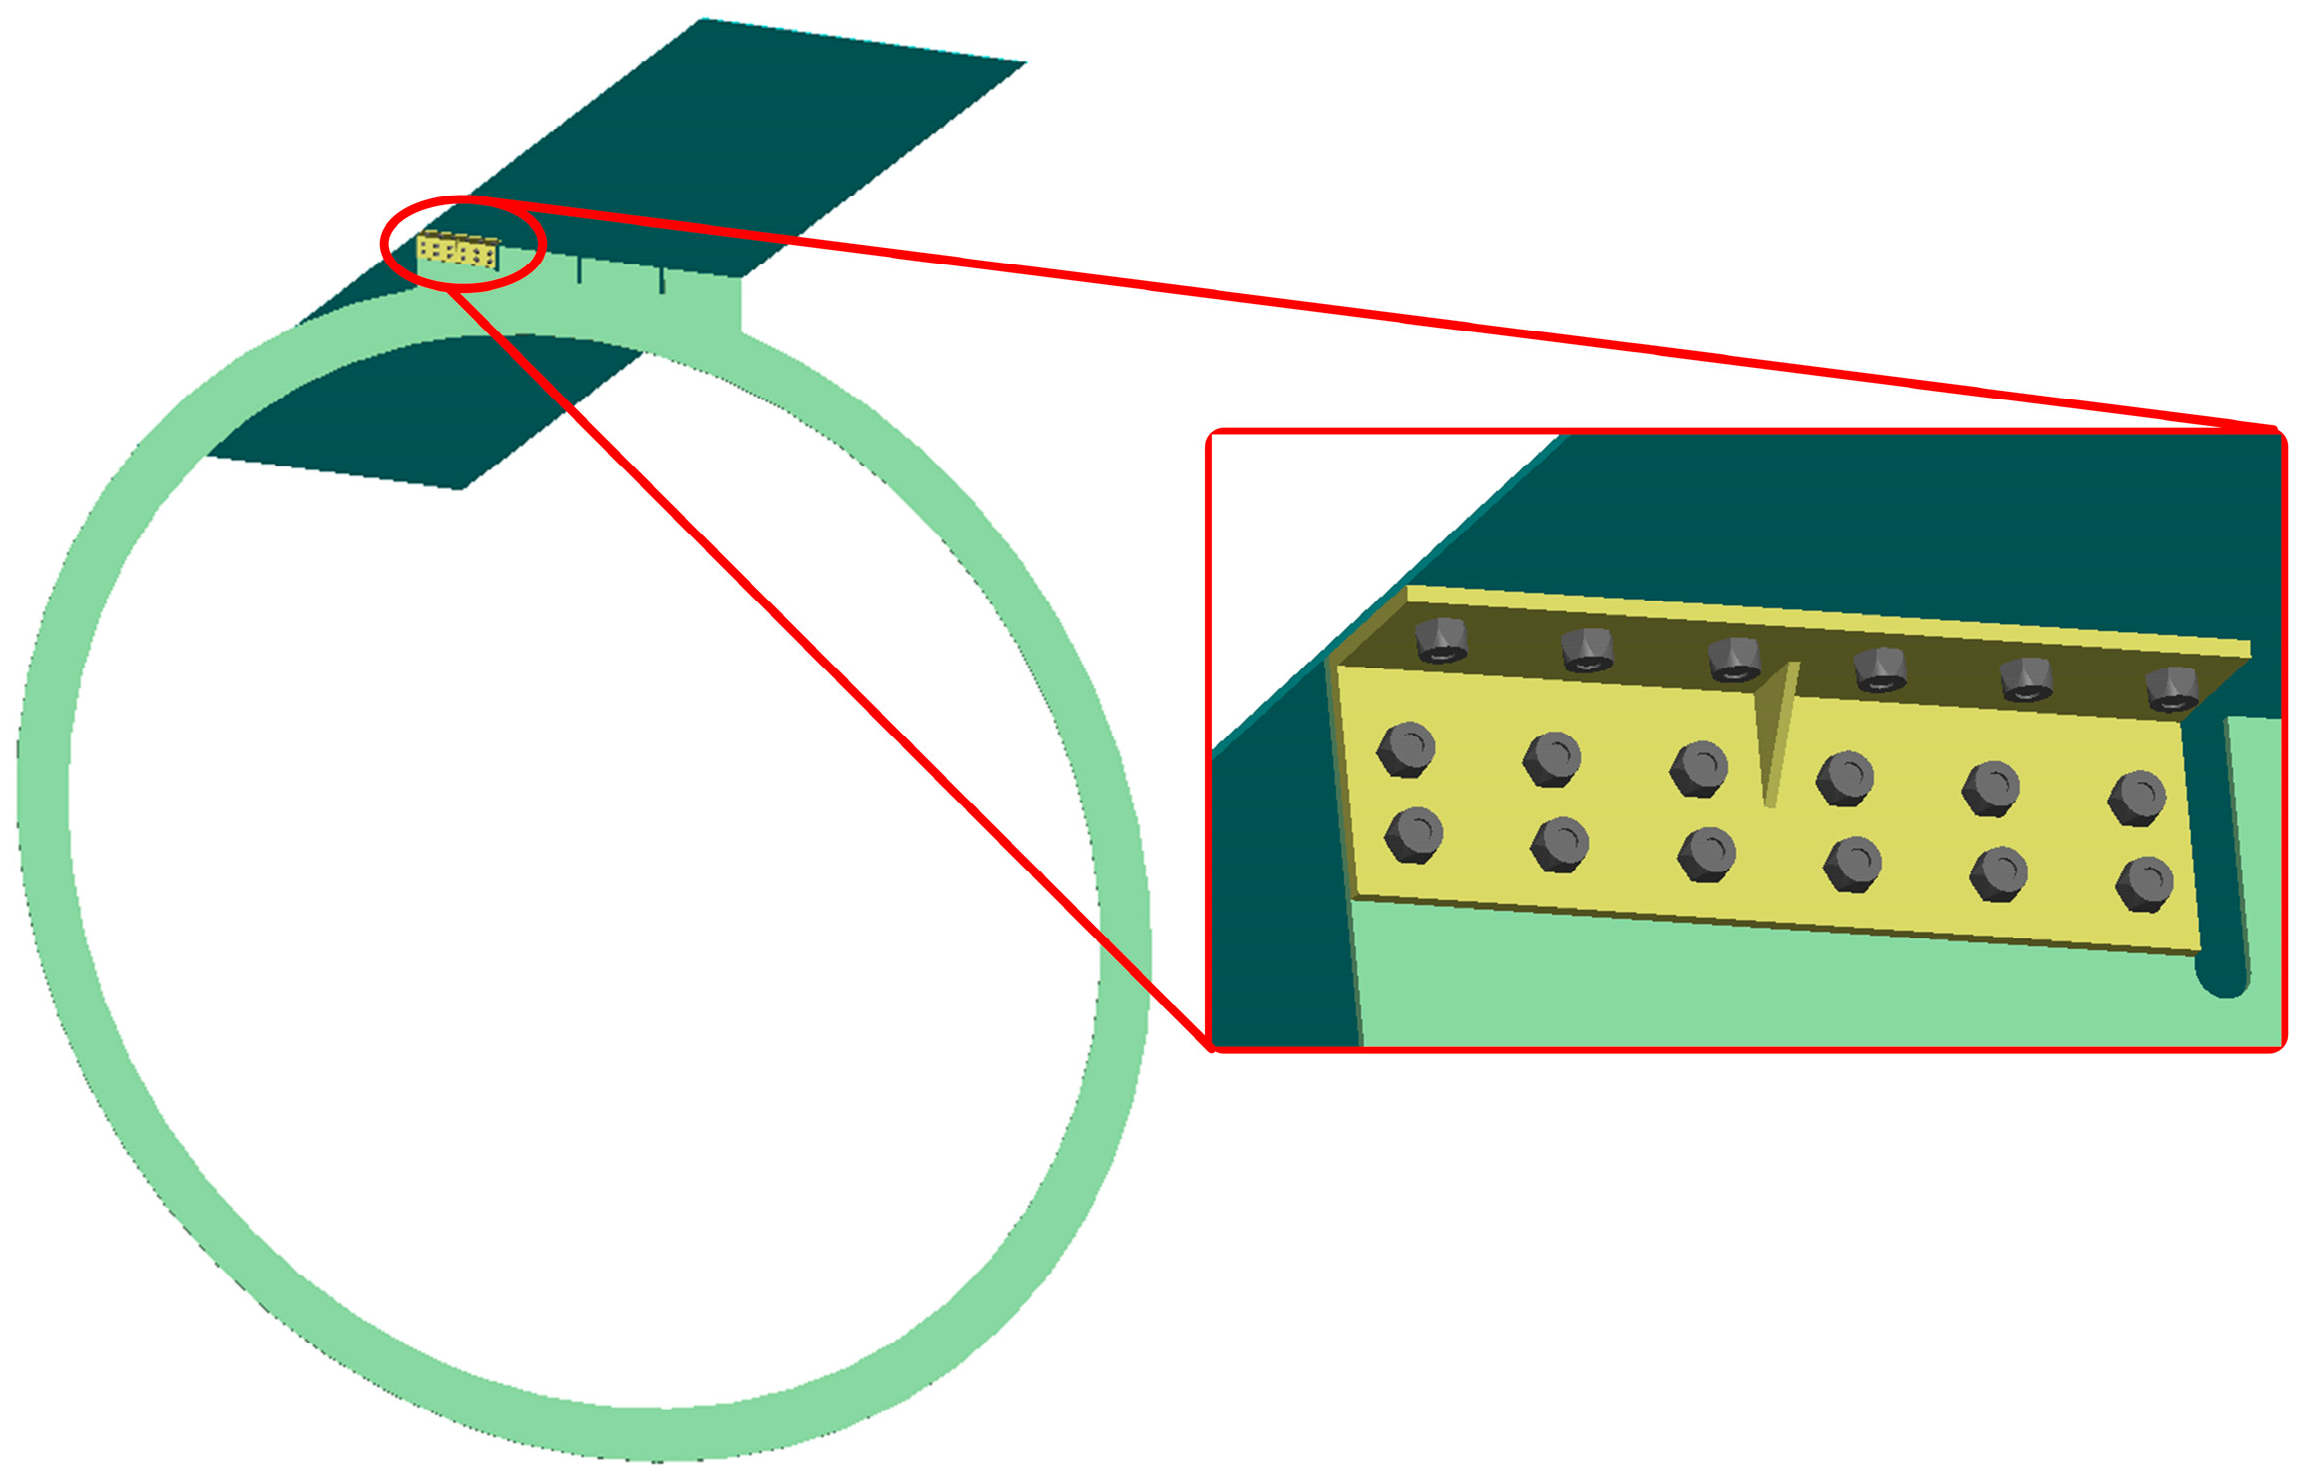
This configuration was selected as the final joint design scheme, and its corresponding 3D structural model was generated, as shown in Figure 8, illustrating the spatial arrangement and assembly scheme of the design.
Figure 8.
A 3D model of the final joint configuration.
4.2. Conceptual Design of the Joint Configuration Between the Engine Nacelle Pylon and Wing Box
To verify the robustness of the aircraft Fastener Joint Configuration design method based on the FPS model, a relatively complex connection scenario in the wing structure is selected as a case study, namely the connection between the engine nacelle pylon and the wing box.
The user requirements are defined as follows: to design a connection between the engine nacelle pylon and the wing box that provides high load transfer capacity while meeting the requirements for engine suspension and maintenance disassembly. The specified parameters of the connected components are the following: the wing box end beam, made of 7075-T6 aluminum alloy with a thickness of 4 mm, subjected to a vertical shear force from the pylon beam (box-type structure) of FQ = 80 kN and a bending moment, with a connection length of 500 mm; the pylon box, made of 2024-T3 aluminum alloy with a thickness of 3.5 mm, which is subjected to the engine’s vertical shear force, bending moment, and torque.
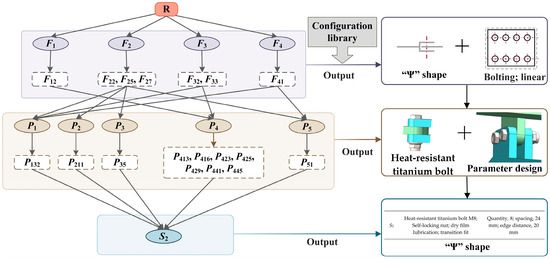
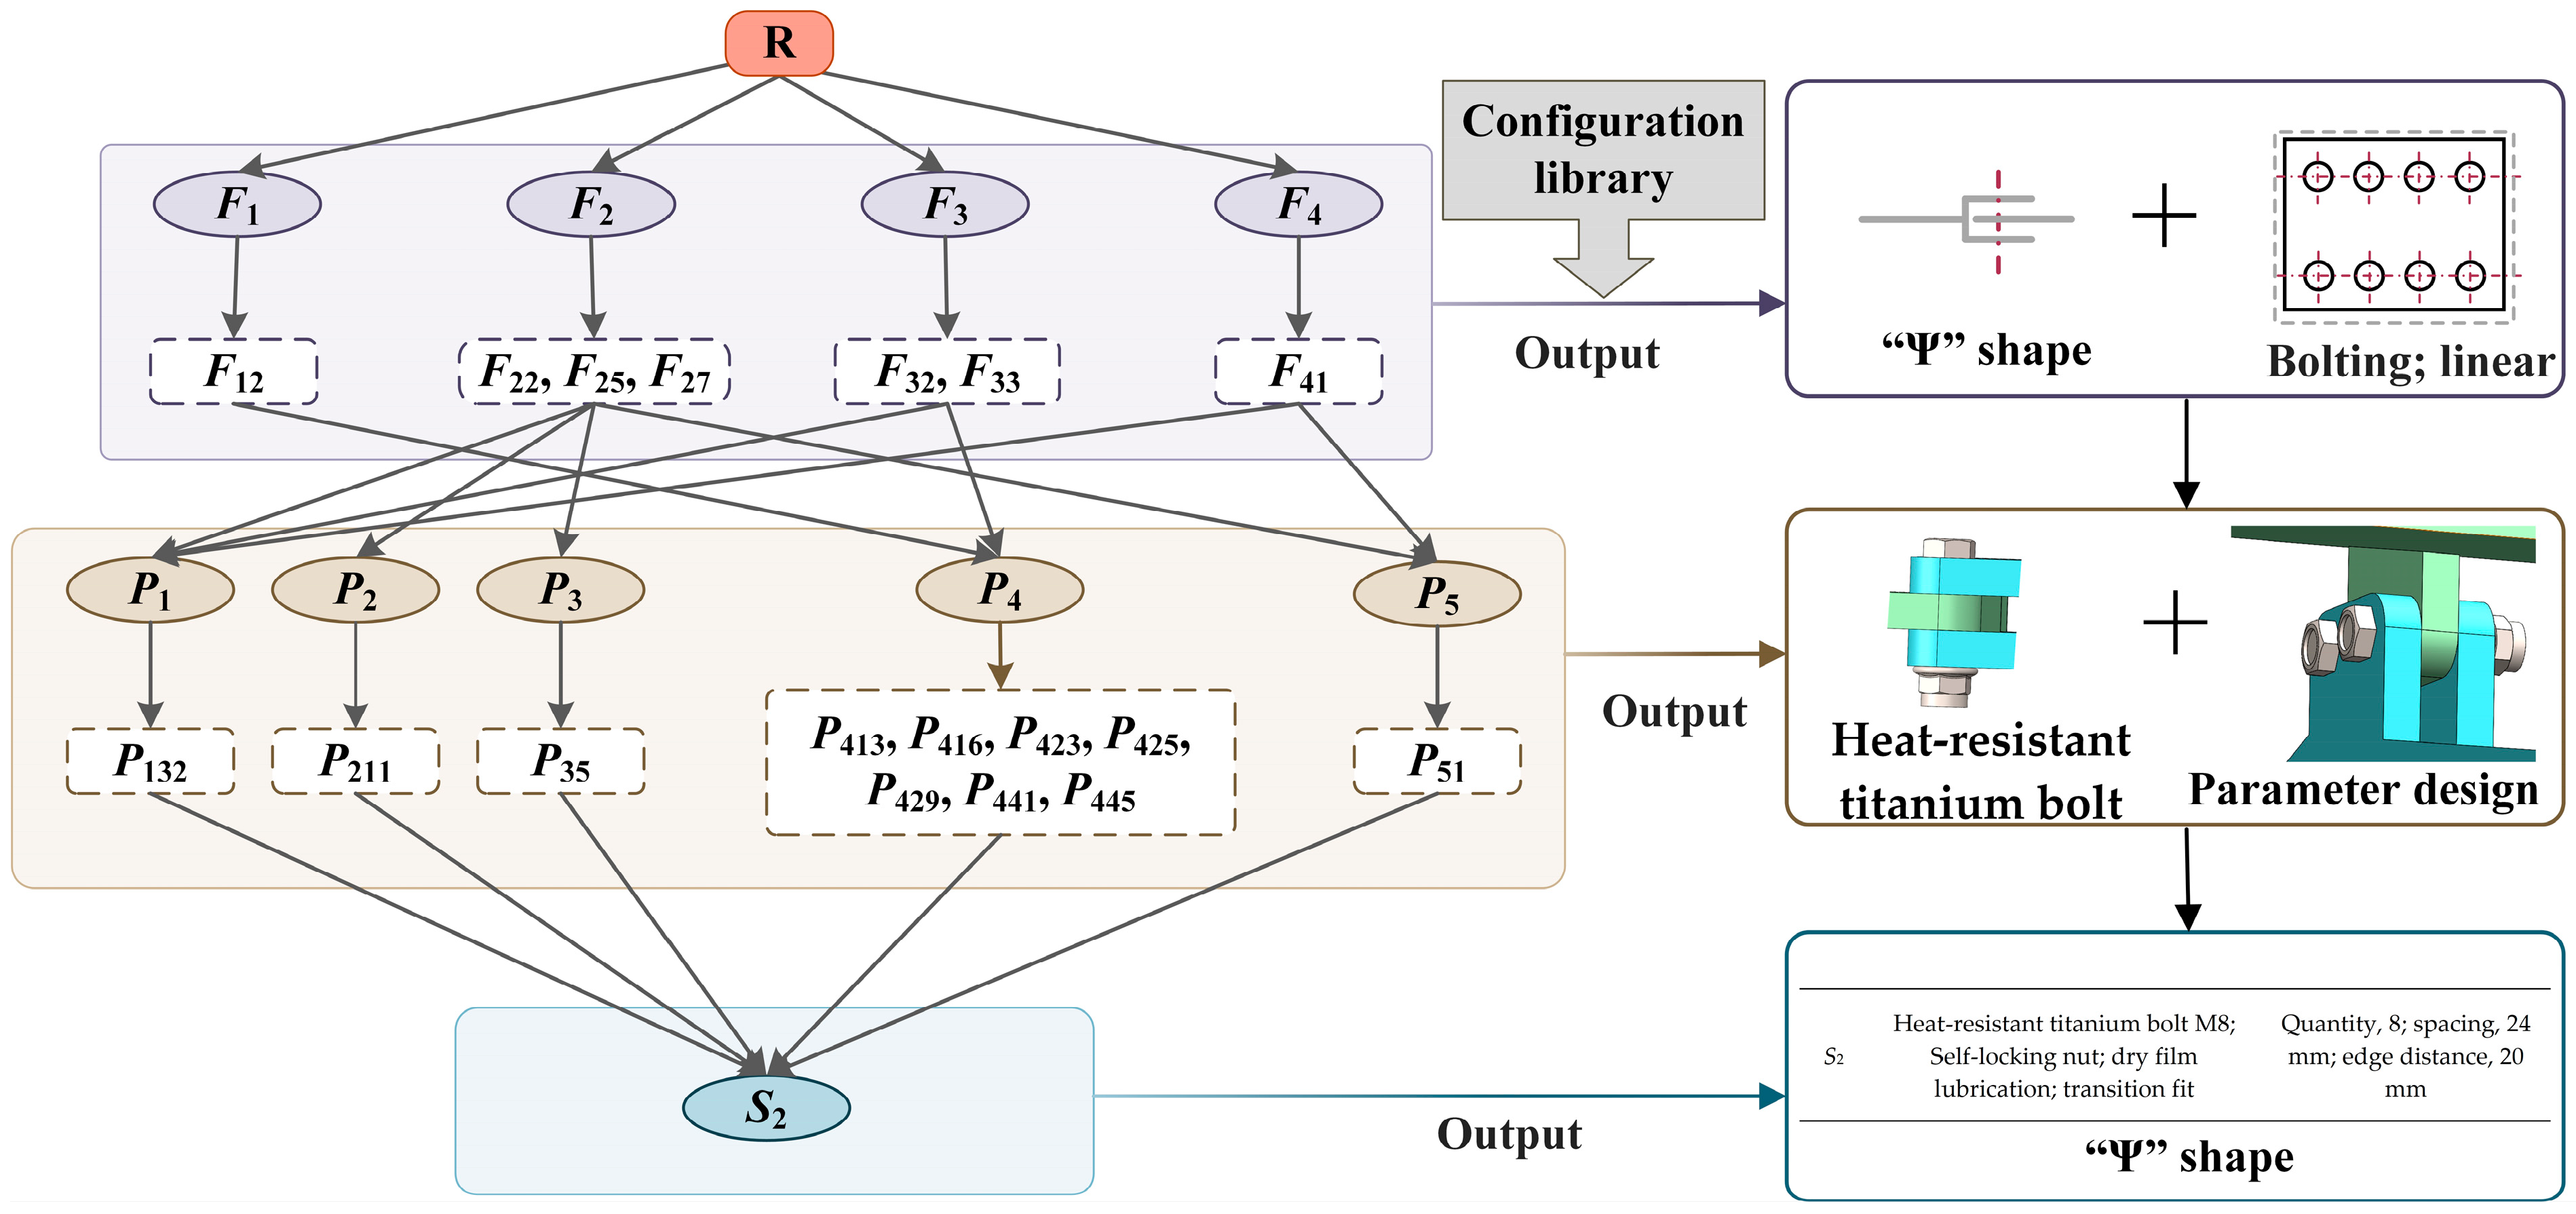
Based on the requirement analysis, the connection location and key load data are explicitly defined, allowing the design of fasteners to be guided by the corresponding cases in the configuration library. According to the functional requirements, since this case simultaneously involves both the wing leading-edge region and the engine nacelle, it corresponds to the sub-functional application scenarios (F2) of aerodynamically sensitive region, high-vibration region, and high-temperature region. Consequently, the functional elements extracted from the F layer are the following: parallel connection (F12), aerodynamically sensitive region (F22), high-vibration region (F25), high-temperature region (F27), subjected to shear force (F32) and bending moment (F33), and detachable connection (F41).
According to the joint location specified, initial combinations of configuration can be referenced from the configuration library. By mapping the functional element F12 and the nacelle pylon–wing box connection into the configuration library (Table 4, Table 5, Table 6, Table 7 and Table 8), the “Ψ” shape joint form is preliminarily selected. For fastener layout, a linear arrangement is chosen to balance load transfer efficiency and spatial compactness. Then, the set of function elements I = {F12, F22, F25, F27, F32, F33, F41} is mapped to the performance layer to derive the associated output set O:
where the output set for P4 is the following:
The output of the performance layer further constrains the parametric design of substructures S2 in the structure layer, resulting in a structure parameter set of the engine nacelle pylon–wing box joint configuration. At this point, the conceptual design flow for the proposed joint configuration is completed, as shown in Figure 9. By integrating the outputs from all three layers, two complete design schemes are ultimately generated, as illustrated in Table 21.
Figure 9.
Configuration design flow for the engine nacelle pylon–wing box joint configuration (R: functional requirements; F: function layer; Fm: subfunctions; Fmn: functional element; P: performance layer; Pm: subperformances; Pmn, Pmnz: performance elements; S: structure layer; and Sm: substructures).
Table 21.
Conceptual design schemes of the engine nacelle pylon–-wing box fastener joint configuration.
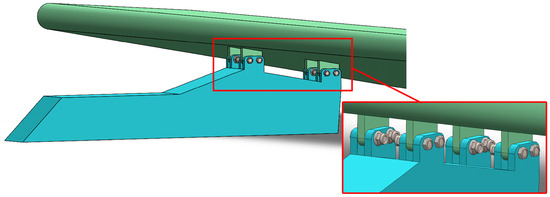
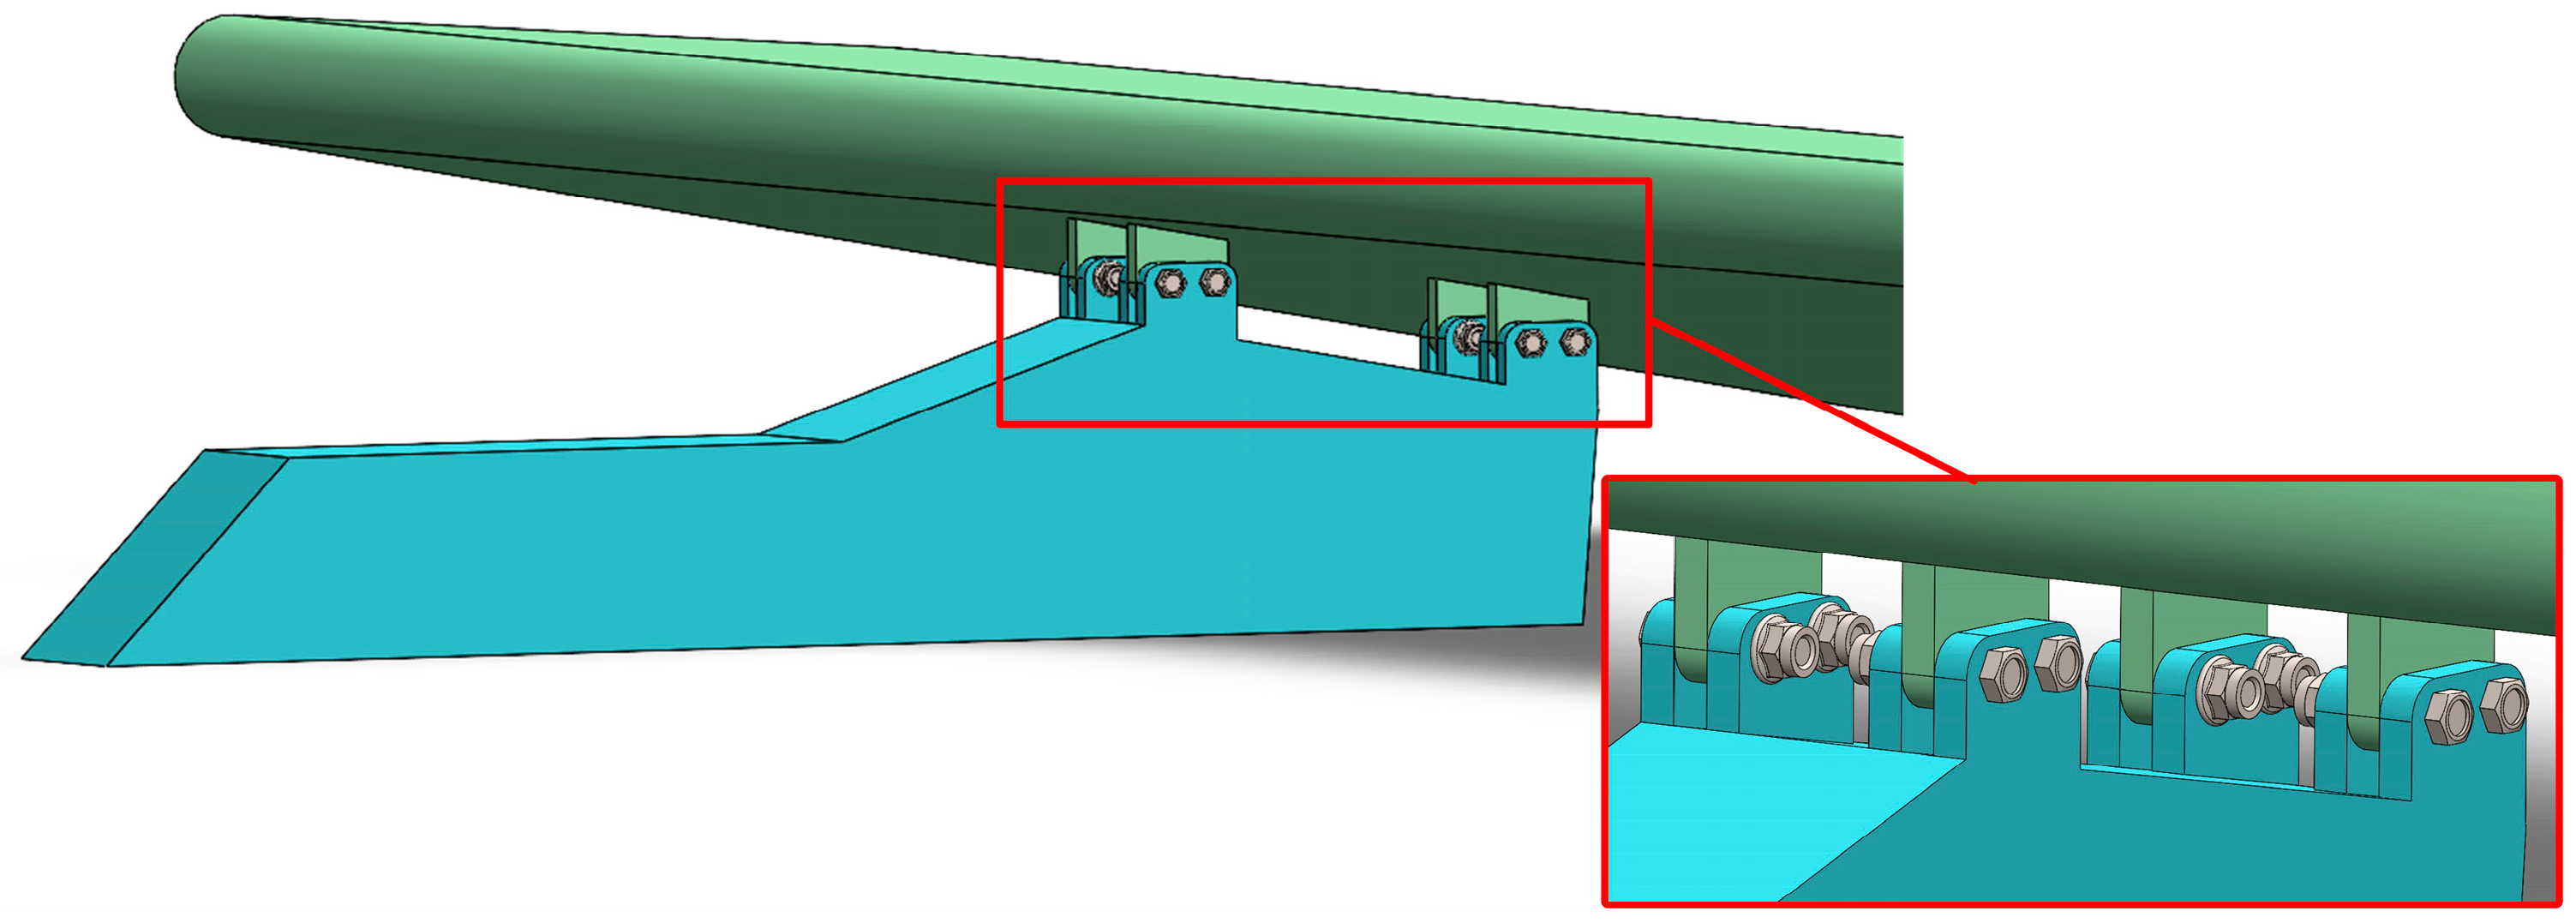
According to the performance indices in Table 18, the design scheme is evaluated. Numerical results show that the fatigue life of the “Ψ” shape structure is far beyond the limiting requirement, the reliability index reaches 3.68, the natural frequency is 22.5 Hz (different from the operating frequencies of the wing and engine), the thermal stress is 289 MPa, and the aerodynamic out-of-plane deformation is 0.5 mm. All indices meet the design requirements. Therefore, the “Ψ” shape structure is determined as the final design solution, and a corresponding 3D structural diagram (Figure 10) is generated to illustrate its spatial configuration and assembly scheme.
Figure 10.
A 3D model of the engine nacelle pylon–wing box joint configuration.
5. Conclusions
To address the lack of systematic methods and clearly defined performance constraints in the design of aircraft fastener joint structures, an FPS based conceptual design methodology for joint structures is proposed. First, service performance requirements are introduced as an intermediary to establish the FPS model. Then, the model and design process are detailed with respect to aircraft structures. Finally, the feasibility and effectiveness of the proposed method are validated through a typical joint configuration design example. This approach integrates conceptual design with structural design and enables a complete reasoning path from user requirements to structural realization.
However, due to the limited availability of data and the rapid development of aerospace equipment design, the configuration library and mapping rules cannot achieve complete coverage and require continuous expansion and refinement. Currently, the current method still relies heavily on manual selection and rule-based mapping. While this approach is effective for conventional joint designs, it may face limitations when dealing with unconventional or novel configurations, where the existing rules may not fully capture unique structural or functional requirements. Future work will focus on expanding the configuration library and mapping rules while incorporating intelligent algorithms and automated modeling tools. In particular, the integration of AI and machine learning techniques (such as knowledge-based reasoning, physics-informed neural networks, or optimization algorithms) will be explored to evolve the methodology into a smart design system with enhanced engineering applicability and decision-making support.
Although the proposed FPS-based conceptual design methodology is developed for aerospace fastener joint structures, its underlying principles are general. With appropriately constructed configuration libraries and carefully selected rule tables, the approach can be adapted to other domains. This underscores the potential broader applicability of the methodology beyond aerospace engineering.
Supplementary Materials
The following supporting information can be downloaded at: https://www.mdpi.com/article/10.3390/pr13092870/s1, Table S1: Schematic representation of components within joint configurations; Figure S1: Internal wing structure; Figure S2: Summary of wing spar joint configurations; Figure S3: Summary of stringer configurations; Figure S4: Skin Joint configurations; Figure S5: Perimeter joint configurations; Figure S6: Concentrated joint configurations; Figure S7: Spar and stringer joint configurations; Figure S8: Opening area structure and joint configurations; Figure S9: Summary of pipeline joint configurations.
Author Contributions
Conceptualization, Q.C., Y.L. and S.M.; methodology, Q.C. and S.M.; case study, Y.L. and S.M.; investigation, S.M., X.H. and J.X.; writing—original draft preparation, S.M.; writing—review and editing, S.M. and J.X.; supervision, S.L. and X.H.; project administration, S.L.; and funding acquisition, S.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research was supported by Tianjin Key Laboratory of Fastening and Joining Technology, China.
Data Availability Statement
The data used to support the findings of this study are included within the article.
Conflicts of Interest
The authors declare that they have no known competing financial interests or personal relationships that could have appeared to influence the work reported in this paper.
References
- An, Q.; Wang, C.; Ma, T.; Zou, F.; Fan, Z.; Zhou, E.; Ge, E.; Chen, M. Aeronautical composite/metal bolted joint and its mechanical properties: A review. J. Intell. Manuf. Spec. Equip. 2024, 5, 70–91. [Google Scholar] [CrossRef] [Scilit]
- Barrett, R.T. Fastener Design Manual; Lewis Research Center: Cleveland, OH, USA, 1990. [Google Scholar]
- Melhem, G.N. Aerospace Fasteners: Use in Structural Applications. In Encyclopedia of Aluminum and Its Alloys; Taylor & Francis Group; CRC Press: Boca Raton, FL, USA, 2019; pp. 30–45. [Google Scholar]
- Barbosa, G.F.; Carvalho, J. Guideline tool based on design for manufacturing and assembly (DFMA) methodology for application on design and manufacturing of aircrafts. J. Braz. Soc. Mech. Sci. Eng. 2014, 36, 605–614. [Google Scholar] [CrossRef] [Scilit]
- Qin, X.; Regli, W.C. A study in applying case-based reasoning to engineering design: Mechanical bearing design. Artif. Intell. Eng. Des. Anal. Manuf. 2003, 17, 235–252. [Google Scholar] [CrossRef] [Scilit]
- French, M.J. Conceptual Design for Engineers; The Design Council: London, UK, 1985. [Google Scholar]
- Andreasen, M.M.; Hansen, C.T.; Cash, P. Conceptual Design; Springer: Cham, Switzerland, 2015. [Google Scholar]
- Zhou, J.; Yu, M.; Zhao, W.; Zhang, K.; Chen, J.; Guo, X. An Iterative Conceptual Design Process for Modular Product Based on Sustainable Analysis and Creative Template Method. Processes 2022, 10, 1095. [Google Scholar] [CrossRef] [Scilit]
- Hyeon, H.J.; Parsaei, H.R.; Wong, J.P. Concurrent engineering: The manufacturing philosophy for the 90’s. Comput. Ind. Eng. 1991, 21, 34–39. [Google Scholar]
- Gero, J.S. Design prototypes: A knowledge representation schema for design. AI Mag. 1990, 11, 26–36. [Google Scholar]
- Gero, J.S.; Kannengiesser, U. A function–behavior–structure ontology of processes. Artif. Intell. Eng. Des. Anal. Manuf. 2007, 21, 379–391. [Google Scholar] [CrossRef] [Scilit]
- Sanderson, D.; Chaplin, J.C.; Ratchev, S. A Function–Behaviour–Structure design methodology for adaptive production systems. Int. J. Adv. Manuf. Technol. 2019, 105, 3731–3742. [Google Scholar] [CrossRef] [Scilit]
- Umeda, Y. Supporting conceptual design based on function–behavior–state modeler. Artif. Intell. Eng. Des. Anal. Manuf. 1996, 10, 275–288. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; He, W.P.; Zhang, D.H.; Cai, H.M.; Yu, S.H. The creative design research of product appearance based on human-machine interaction and interface. J. Xiamen Univ. Nat. Sci. 2002, 41, 152–153. [Google Scholar] [CrossRef] [Scilit]
- Qin, H.; Wang, H.W.; Johnson, A.L. A RFBSE model for capturing engineers’ useful knowledge and experience during the design process. Robot. Comput. Integr. Manuf. 2017, 44, 30–43. [Google Scholar]
- Deng, Y.M. Function and behavior representation in conceptual mechanical design. Artif. Intell. Eng. Des. Anal. Manuf. 2002, 16, 343–362. [Google Scholar] [CrossRef] [Scilit]
- Yannou, B.; Cluzel, F.; Lamé, G. Adapting the FBS model of designing for usage-driven innovation processes. In Proceedings of the International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Quebec City, QC, Canada, 26–29 August 2018; p. V007T06A011. [Google Scholar]
- Russo, D.; Spreafico, C.; Duci, S. On the co-existence of FBS and TRIZ for simplifying design process in an iterative way. In Proceedings of the DS 75-2: 19th International Conference on Engineering Design (ICED13), Seoul, Republic of Korea, 19–22 August 2013. [Google Scholar]
- Li, X.; Zhang, K.; Zhao, W.; Zeng, K. A Knowledge Push Approach to Support the Green Concept Design of Products. Processes 2023, 11, 2891. [Google Scholar] [CrossRef] [Scilit]
- Fu, X.; Zhang, H.; Jing, L.; Fan, X.; Lu, C.; Jiang, S. A constraint-driven conceptual design approach for product based on function–behavior–structure design process. Comput. Ind. Eng. 2024, 189, 109994. [Google Scholar] [CrossRef] [Scilit]
- Gui, F.; Zhou, J.; Sun, X.; Lu, J.; Cao, S. An Extenics–TRIZ integrated RFPS model for different object of design requirements. PLoS ONE 2025, 20, e0316138. [Google Scholar]
- Cao, J.; Zhao, W.; Hu, H.; Liu, Y.; Guo, X. Using Linkography and Situated FBS Co-Design Model to Explore User Participatory Conceptual Design Process. Processes 2022, 10, 713. [Google Scholar] [CrossRef] [Scilit]
- Hua, H.; Zhang, Z.; Feng, H. Research Status and Method of Aviation Sensor Performance Evaluation. J. Phys. Conf. Ser. 2021, 1769, 012050. [Google Scholar] [CrossRef] [Scilit]
- Sui, L.; Sun, Y.; Kang, M. Analysis and Experimental Study for Fatigue Performance of Wing-Fuselage Connection Structure for Unmanned Aerial Vehicle. Aerospace 2024, 11, 826. [Google Scholar] [CrossRef] [Scilit]
- Hassanzadeh, A.; Moradi, S.; Burton, H.V. Performance-based design optimization of structures: State-of-the-art review. J. Struct. Eng. 2024, 150, 03124001. [Google Scholar] [CrossRef] [Scilit]
- Wein, F.; Dunning, P.D.; Norato, J.A. A review on feature-mapping methods for structural optimization. Struct. Multidiscip. Optim. 2020, 62, 1597–1638. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.; Li, Y.; Chen, J.; Tao, Y.; Xia, W. A structure mapping–based representation of knowledge transfer in conceptual design process. Proc. Inst. Mech. Eng. Part B J. Eng. Manuf. 2020, 234, 400–420. [Google Scholar] [CrossRef] [Scilit]
- Deng, Y.M.; Zhu, Y.W. Function to structure/material mappings for conceptual design synthesis and their supportive strategies. Int. J. Adv. Manuf. Technol. 2009, 44, 1063–1072. [Google Scholar] [CrossRef] [Scilit]
- Barrett, R.T. Fastener Design Manual; NAS 1.61:1228; National Aeronautics and Space Administration: Washington, DC, USA, 1990. [Google Scholar]
- Wen, C.; Zhu, Z.; Fu, X.; Long, T.; Li, B. Dynamic Analysis of a Bolted Joint Rotor-Bearing System with a Blade–Casing Rubbing Fault. Processes 2023, 11, 2379. [Google Scholar] [CrossRef] [Scilit]
- Mordfin, L. Some problems of fatigue of bolts and bolted joints in aircraft applications. NASA Tech. Rep. 1962, 136, 1–36. [Google Scholar]
- Steeve, B.E. Aerospace Threaded Fastener Strength With Joint Shims; M-1506; National Aeronautics and Space Administration: Washington, DC, USA, 2020. [Google Scholar]
- Sadri, S.M. Aerospace Bolts. In Handbook of Bolts and Bolted Joints; CRC Press: Boca Raton, FL, USA, 1998; pp. 184–190. [Google Scholar]
- Niu, M.C.Y. Airframe Stress Analysis and Sizing, 2nd ed.; Conmilit Press: Hong Kong, China, 1999. [Google Scholar]
- Chaves, C.E.; Fernandez, F.F. A review on aircraft joints design. Aircr. Eng. Aerosp. Technol. Int. J. 2016, 88, 411–419. [Google Scholar] [CrossRef] [Scilit]
- RPrakash, U.; Udaya, G.R.; Vijayanandh, R.; Kumar, M.S.; Ramganesh, T. Structural analysis of aircraft fuselage splice joint. In Proceedings of the IOP Conference Series: Materials Science and Engineering, Bangalore, India, 14–16 July 2016; Volume 149, p. 012127. [Google Scholar]








Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).