


Abstract
Modern agriculture requires optimizing available resources to maximize production while minimizing environmental impact without increasing economic costs. Hydroponic agriculture replaces soil with inert media that provide physical support for plants but do not supply nutrients. In this type of agricultural production, fertilization with nutrient solutions is essential, as they supply the 15 elements necessary for proper plant development. These solutions consist of mixtures of different amounts of fertilizers dissolved in water. In this context, a method based on a simulated annealing algorithm is proposed, a metaheuristic that optimizes fertilizer quantities in grams to achieve target concentrations in parts per million for six macronutrients and nine micronutrients. The algorithm addresses a multi-objective optimization problem, balancing two competing goals: first, maximizing the accuracy of the fertilizer balance to achieve the required nutritional levels, and second, minimizing the total cost of the fertilizer mixture. The algorithm’s fitness function weights the total cost of the fertilizers used and the total relative error between the concentrations obtained and those desired, allowing the relative importance of cost and accuracy in the nutrient solution to be adjusted. The results of three experiments with varying nutrient levels are presented for a 1000-L water tank. The first experiment consisted of three macronutrients and two micronutrients. The second configuration added three macronutrients and two micronutrients, for a total of ten nutrients. Finally, five micronutrients were added to complete the 15 essential nutrients for plants. It is important to note that there are several methods for calculating micronutrients that contribute to precision agriculture, increasing the complexity of finding a solution that meets established nutritional requirements. The nutrient concentrations in parts per million required for tomato cultivation during the vegetative development stage. To balance nutrient accuracy and solution cost, we applied weighting factors of and for accuracy. The corresponding weights for cost were calculated as the complement of these values (totaling 1). By favoring nutrient accuracy with a weighting of 1, accuracies of 0.00500, 0.02618, and 0.03077 parts per million were achieved in each experiment, respectively. Meanwhile, the lowest cost is , , and USD for the aforementioned experiments.
1. Introduction
Agriculture is a pillar of human sustenance and the development of civilizations around the world [1,2]. It supports population growth by producing sufficient food in terms of quantity and quality, ideally without increasing costs or environmental impact. By 2050, the United Nations [3] forecasts a world population of approximately 10 billion, which poses challenges in a context of declining arable land, which currently represents of the Earth’s surface [4] but produces increasingly more food, making it necessary to seek sustainable alternatives, such as hydroponics, instead of extensive practices.
Recent technological advances in tillage have given rise to Precision Agriculture (PA), which uses statistics and different types of algorithms, ranging from classic to Artificial Intelligence (AI), such as Computer Vision (CV) [1], Deep Learning (DL), and Metaheuristics (MA) [5,6]. PA aims to increase crop yields and resource efficiency by monitoring crop characteristics such as growth, leaf and fruit color, and health, while optimizing irrigation and fertilization to reduce environmental impact and detect pests and diseases [7,8,9].
Simulated Annealing Algorithm (SA) is inspired by a metallurgical process. Annealing constitutes a heat treatment process in metallurgy wherein a metal is heated to an elevated temperature to enhance atomic mobility, followed by controlled cooling to attain a minimum-energy crystalline structure, thereby improving ductility and relieving internal stresses. The SA represents a trajectory-based stochastic metaheuristic tailored for global optimization in search spaces exhibiting complex topologies with multiple local optima [10].
This document develops and presents an adapted SA method for formulating hydroponic nutrient solutions, highlighting key aspects: applicability across diverse hydroponic crops, effectiveness in meeting crop specific nutritional requirements, substantial fertilizer cost reductions via a weighting parameter balancing both factors without compromising nutrient adequacy and most methods in the literature focus on the three main macronutrients, while the method presented here covers the elements that are essential for plant development.
The organization of the paper is as follows: Section 2 presents a series of works related to land cultivation processes for food production in PA. Section 3 The materials and methods used in the SA adaptation for the formulation of nutrient solutions for crops are described. The objectives of the experiment and the control parameters for the formulation of nutrient solutions using SA are presented in Section 4. The results obtained with the adaptation of the algorithm for the formulation of nutrient solutions are presented in the Section 5 and the Section 6 contains the conclusions of the research.
2. Related Works
The technification of agricultural processes with the aim of achieving the objectives of the PA has led to the use of different types of hardware and software, which are constantly updated to improve their efficiency. The use of intelligent algorithms has recently been used in several tasks such as identification of pests, diseases [11,12], classification of plant components in crops [13,14,15], and optimization of irrigation and fertilization processes [16,17].
Various methods have been reported in the literature for PA to determine the levels of certain chemical elements in crops, with a focus on nitrogen, phosphorus, and potassium. Lu [18] used 340 groups of images with different potassium contents to establish the relationship between reflectance spectra and leaf K content. Qi [19] proposed a method for determining the nitrogen content in images of wheat crops acquired with mobile devices using histogram manipulation algorithms. Phosphorus is another of the main macronutrients for crop development. Li [20] presented a method for measuring how phosphorus concentration affects electrical impedance in tomato crops. Sun [21] used dynamic leaf capture of rice leaves by scanning to investigate the changing regulation of leaf characteristics under nutritional stress from nitrogen, phosphorus, and potassium. Leaf characteristics were determined using the mean value and regionprops functions, and leaf dynamics were quantified by calculating the relative growth rate. Tran [22] implemented the Inception-ResNet v2 convolutional neural network model and Autoencoder to classify and predict calcium, potassium, and nitrogen deficiencies.
Once a nutrient deficiency has been identified, the next step in PA is to correct the condition through fertilization processes that must be both effective and efficient. For example, Cropper [17] developed a model to estimate the amount of phosphorus present in the soil and crop requirements in order to use a genetic algorithm to estimate the minimum amount needed to meet crop needs through fertilization processes. Xu [23] developed an expert system to support decision-making regarding nitrogen, phosphorus, and potassium fertilization processes, using data from 2000 plant nutrition experiments, reporting an increase in rice grain production in fields that used the recommendations made by the expert system. Ahmad [24] estimated the amount of nitrogen needed based on the water required for its application using a quadratic equation that can be used to reduce costs across different crops. Ahmed [25] implemented a genetic algorithm that uses data from different types of sensors to make adjustments to fertilization processes, using the neighborhood-based strategy for the exploration and exploitation stages. Chen [26] proposed an optimization method based on an optimization algorithm inspired by the behavior of the gray wolf with multiple strategies to make fertilization suggestions for the main macronutrients.
3. Materials and Methods
The following sections describe the fundamental concepts of the formulation of nutritional solutions, characteristics of the crop selected for experimentation, and the explanation of the method for Formulating Nutrient Solutions Using Simulated Annealing (FNSUSA).
3.1. Plant Nutrition
Through photosynthesis, plants obtain essential elements such as Oxygen (O), Carbon (C), and Hydrogen (H). Additionally, proper plant development requires 15 other essential chemical elements, which are divided into two categories: six macronutrients [27] and nine micronutrients [28]. This division is based on the quantity required, not on their relative importance. The elements belonging to the first category are required in greater quantities compared to elements belonging to the second category; for macronutrients, the range is from 30 to 400 PPM and for micronutrients, it is 0.01–5 PPM [29], emphasizing that each crop has specific needs. Table 1 shows the chemical elements belonging to each category.
Table 1.
List of 15 nutrients necessary for proper plant development.
Soilless cultivation of various crops, primarily vegetables, in greenhouses requires a consistent, efficient, and effective fertilization process [30]. This approach enhances both the quantity and quality of harvests, enables off-season production, and opens opportunities for accessing export markets, among other benefits. To provide crops with essential resources for growth that are not acquired through photosynthesis, different amounts of fertilizers are mixed or dissolved in 1000 L of water in one-cubic-meter tanks, which are commonly used in hydroponics. The mixture is called the Nutrient Solution (NS). Table 2 shows the chemical composition of some fertilizers commonly used in the composition of NS. Fertilizer prices were taken directly from online shopping sites such as eBay (https://mx.ebay.com accessed on 4 November 2025), Amazon (https://www.amazon.com.mx accessed on 14 November 2025), and MercadoLibre (https://www.mercadolibre.com.mx accessed on 10 December 2025).
Table 2.
List of fertilizers to be considered for blending.
The total cost of an NS is calculated by adding the price of each fertilizer used in the mixture by the amount in grams used, which is expressed in the following equation:
where n is the number of fertilizers available to formulate the NS; is the amount of each fertilizer expressed in grams for mixing; refers to the cost by kg of fertilizer f on the market.
To formulate NS, it is necessary to calculate the Parts Per Million (PPM) of each Nutrient chemical element present in a given amount in grams of fertilizer. The PPM of a specific element is calculated using the following equation:
where f refers to a particular fertilizer, and e is the nutrient that forms part of the fertilizer, 1000 is constant conversion factor to convert grams of fertilizer to milligrams, is the amount in grams of fertilizer, is the atomic weight of the element selected for its quantification, is the number of atoms of the chemical element present in chemical formula of one fertilizer particularly, is the fertilizer molecular weight and V is total volume of the NS in liters.
NS is a mixture of various quantities of fertilizers, each of which contributes a different PPM of the nutrient elements. Therefore, it is necessary to quantify the total PPM of each chemical element present in the NS. The following equation is used to determine the PPM of the different Nutrient elements:
where represents the total concentration of the nutrient element e present in the NS, while corresponds to the amount of PPM contributed by a specific amount of fertilizer f for nutrient element e, calculated by applying Equation (2).
3.2. Algorithm for Formulating Nutritious Solutions Using Simulated Annealing
Simulated Annealing (SA) is a metaheuristic algorithm inspired by the metallurgical process of annealing, in which a material is slowly cooled to reach a minimum-energy state. Its primary strength lies in its ability to escape local optima, making it ideal for complex combinatorial optimization problems with vast search spaces, such as the Formulation. The algorithm operates by iteratively exploring solutions, starting at a high initial “temperature”. In each step, a neighboring solution is generated; better solutions are always accepted, while worse solutions may also be accepted based on a probabilistic criterion tied to the current temperature. Initially, this allows the algorithm to broadly explore the solution space (exploration phase). As the process continues, the temperature is gradually reduced according to a cooling schedule, which decreases the probability of accepting worse solutions. This shifts the search from exploration to exploitation, allowing the algorithm to converge towards a globally optimal solution. The main control parameters are the initial and final temperatures, the cooling factor, and the number of iterations at each temperature level [31].
It is necessary to initially assign a quantity, in grams, of each available fertilizer for the formulation of the NS. This is done by applying the Equation:
where the quantity in grams for fertilizer f is between the lower limit () and the upper limit (), which are used for all fertilizers available for the formulation of NS.
The algorithm begins by creating a random initial candidate solution in the search space, which is as follows:
where n is the number of fertilizers available for the formulation of NS.
The SA explores the search space by introducing a perturbation in the . The perturbations for each are determined based on the following equation:
where represents the upper limit of the perturbation to explore the search space, which is in the range . This value decreases linearly with the system temperature, allowing the exploitation stage to be emphasized.
The increase or decrease for is determined by the following equation:
SA requires a second solution to the problem to be optimized, which is constructed from applying the following equation:
where is the candidate solution constructed from . The quantities of each fertilizer are increased or decreased randomly, with the same probability of occurrence.
It is important to note that cannot be negative. If a negative value is generated for any , it will take the value of 0.
FNSUSA is a random optimization algorithm whose main feature is that, at the beginning of execution, it favors exploration of the search space, allowing it to accept solutions that are not necessarily better than the current one. As the current solution’s fitness approaches the convergence condition, the exploitation stage of the search space is emphasized.
The objective of FNSUSA is to identify a fertilizer formulation that achieves the target concentrations in PPM for the macronutrients and micronutrients specified in Table 2. The target PPM is defined by the following equation:
where subscript e refers to the nutrient element established as the target to be achieved in the final NS in PPM.
Relative error is an option for measuring the accuracy of the NS PPMs in relation to the target PPMs. It is expressed using the following equation:
where is the absolute relative error of nutrient e, in relation to the defined in Equation (3) with respect to .
The total relative error in the NS is determined by applying the Equation:
Subindex e takes values from 1 to the total number of nutrients considered in the objective function of the FNSUSA.
The success of metaheuristic algorithms, including SA, largely depends on how the cost or fitness function is modeled. In the case of FNSUSA, the fitness function is a linear weighted sum combining two metrics: and . This is expressed in the following equation:
where is the preponderance factor between the total relative error and the cost of NS, it must take a value in the range ; similarly, this value acts as a normalizer between the two parameters to be weighted. It is important to mention that as the total relative error tends to 0, the cost of NS will naturally take on greater importance in determining the fitness of an NS.
The initial temperature and the model for its reduction (the cooling schedule) are key parameters for controlling the algorithm’s exploration phase. The initial temperature [32] of the FNSUSA is calculated using the following equation:
where is the difference between the fitness of the initial solution and the candidate solution, and p is the desired probability of accepting worse solutions at the start of the FNSUSA.
The temperature parameter is reduced geometrically, applying the following equation:
where is an initial value that must be in the range [0, 1]; a value close to 1 generates a slight decrease in temperature, while a value tending to 0 causes accelerated cooling. The decrement factor is calculated using Equation:
where is the desired final temperature of the system or convergence condition, and I is the number of energy states through which the system passes.
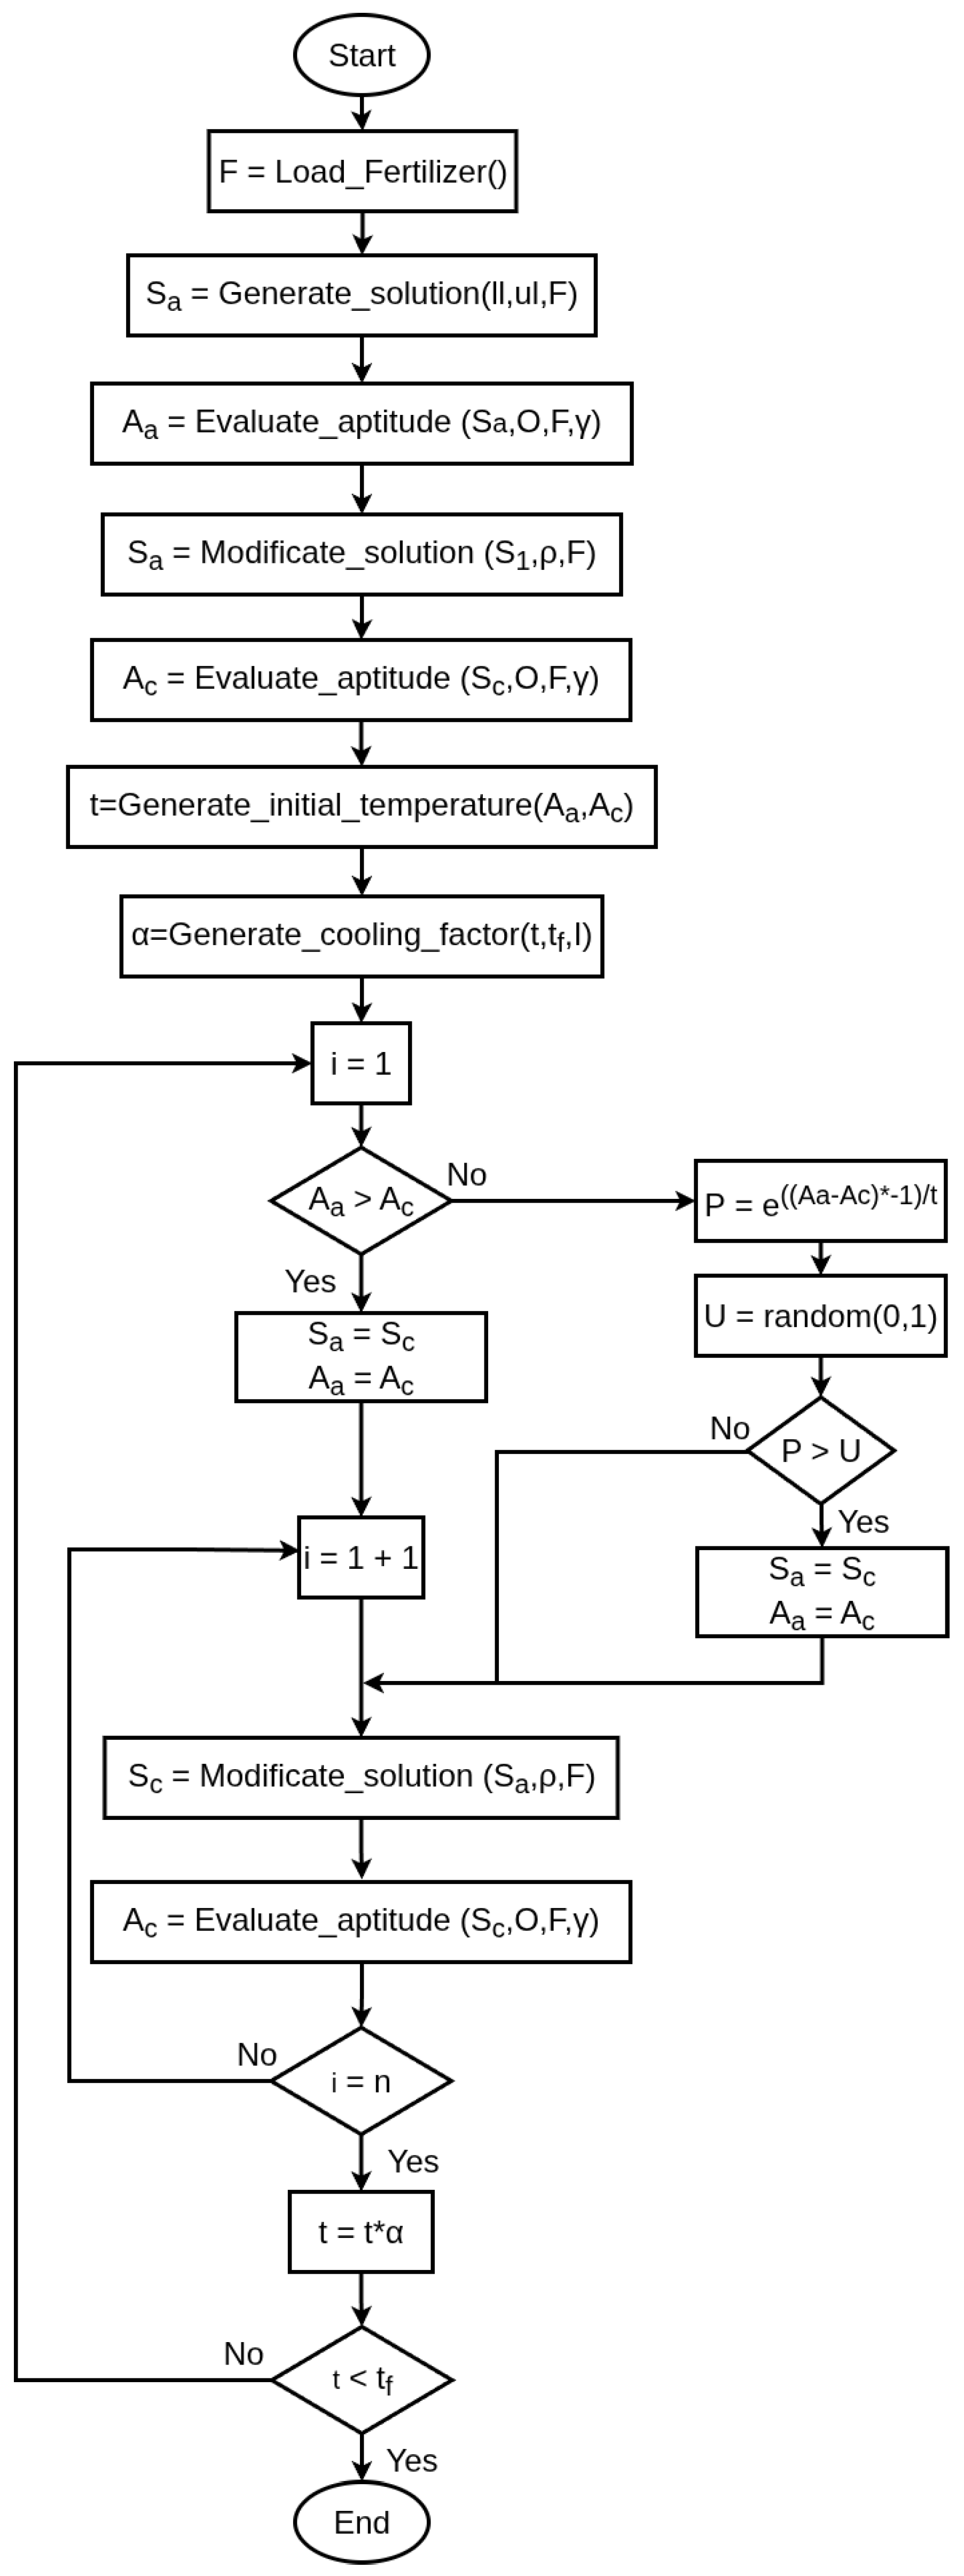
Figure 1 illustrates the adaptation of the SA algorithm for formulating hydroponic Nutrient Solutions.
Figure 1.
Adaptation of the SA for formulation NS.
The diagram outlines the primary functions responsible for implementing the previously described equations. A general description of each function, its parameters, and its return values is provided in Table 3.
Table 3.
Description of FNSUSA functions.
3.3. Development Environment and Computer Specifications
The programming language in which the algorithm in Figure 1 was implemented was Python version 3.9.15, due to the number of libraries available. The hardware characteristics are necessary to provide a reference for the time required for the FNSUSA algorithm to reach the target PPM.
The characteristics of the computer equipment that was used were as follows:
- Manufacturer: ASUSTeK COMPUTER INC., Taipei City, China
- Modelo: X510UNR
- Processor: Intel® Core™ i7-8550U CPU @ 1.80 GHz × 8.
- RAM: 16 GB.
- Operating system: Ubuntu 22.04.2 LTS 64 bits.
4. Experimentation
The efficiency of the FNSUSA algorithm is measured in two ways. The first scenario evaluates the algorithm’s effectiveness in achieving the target PPMs (for macronutrients or micronutrients). This is achieved by assigning , a parameterization that (based on Equation (12)) nullifies the cost component, forcing the optimization to focus exclusively on technical effectiveness. The second scenario tests the method’s ability to balance achieving the PPM against a lower price. For this test, the cost is explicitly considered by assigning a value between zero and one . A total of 180 FNSUSA executions are reported, 10 for each of the six values tested, giving a total of 60 executions and 3 different target configurations, for a total of 180.
4.1. Characteristics of Selected Crop for the Step of Experimentation
Our experimental stage focuses on the tomato, a member of the Solanaceae family with its origins in the Americas. There are two hypothesized beginnings for its domestication: one in the mountainous areas of Peru and Ecuador, and the other in the Aztec Empire’s Tenochtitlan [33]. The tomato crop has several developmental stages during its growth, which differ in terms of water and nutrient requirements versus the development of the plant itself. The developmental stages are as follows:
- Plant establishment: Tomato is a crop that can be annual or perennial. It germinates four to seven days after the seed is sown. The root begins to develop, and the formation of the aerial part of the plant begins.
- Vegetative growth: In this period, the plant grows rapidly, flowering and developing fruit. After 70 days, vegetative development is minimal, as well as the accumulation of dry matter in leaves and stems. Development.
- Flowering and fruit set: Flowering and fruit set begin about 20–40 days after transplanting and continue during the rest of the growth cycle.
- Fruit development: The fruit begins to develop and grow, accumulating in this period the greatest amount of dry matter in the fruit at a relatively stable rate.
- Physiological maturity and harvest: Fruit maturity is achieved between 80 and 120 days after transplanting. Harvesting is permanent.
4.2. Results of FNSUSA
Three different nutritional objectives are presented as targets for the FNSUSA. These objectives are defined by the number of macronutrients and micronutrients to be balanced, starting at five and increasing to 15 essential nutrients, for tomato cultivation during its vegetative growth stage [34,35]. The combination of macronutrients and micronutrients for each fitness function is shown in Table 4.
Table 4.
Target PPM in the experimental stage.
As illustrated in Figure 1, FNSUSA requires several key parameters to guide its execution. These parameters are essential for formulating an NS that satisfies the objectives defined by the fitness function. The specific values configured for this implementation are as follows:
This specific parameter set was established to ensure the algorithm properly explores the solution space while balancing search breadth with an efficient convergence speed.
5. Results
The results presented apply FNSUSA to balance the relationship between the , measured as the relative error between the target PPMs and those contained in the NS, and the cost of NS, using different values assigned to . The first configuration has five nutrients, three macronutrients and two micronutrients; the second configuration adds the remaining three macronutrients and two micronutrients, for a total of ten target PPMs; the final arrangement adds the remaining five micronutrients for a total of 15 PPM targets to achieve.
Ten FNSUSA runs are performed for each of the three experimental configurations of target PPM presented in Table 4. To evaluate the algorithm’s efficiency in balancing total error () and cost within the NS formulation, the weighting parameter was tested at values of and . This approach allows for a precise calibration of the trade-off between accuracy and nutrient solution costs.
5.1. Results Generated by FNSUSA in Configuration Targets 1
The first set of targets includes the macronutrients N, P, and K, which are the most important for all crops, along with the micronutrients Cl and Na. It highlights the difference in target PPM concentrations between macronutrients and micronutrients, which reflects the quantitative requirements of crops between the two nutrient classifications.
Table 5 presents the numerical values for , , and obtained in the ten runs of the FNSUSA algorithm for the first experimental configuration, which comprises five Nutrient chemical elements. These results correspond to the different weightings of the parameter, the best result obtained is highlighted in yellow.
Table 5.
Results generated by FNSUSA for experiment 1 with different values.
Table 6 shows the statistical data from the 60 FNSUSA runs for the first experiment. The standard deviations for each gamma value are small compared to the mean, which highlights the repeatability of the results generated.
Table 6.
Statistics for the results in Table 5.
Table 7 contains the quantitative data for the PPMs contained in the NS and their relative error from the best NS formulated using FNSUSA from Table 5.
Table 7.
Comparison of the best solutions in experimental configuration 1 with different values.
Figure 2 shows the quantities expressed in grams of each fertilizer in Table 2 required to formulate the best NS by applying FNSUSA from the first experimental configuration for different values.
Figure 2.
Distribution of the weight for each fertilizer available in Table 2 for the best NS generated for the first experimental configuration.
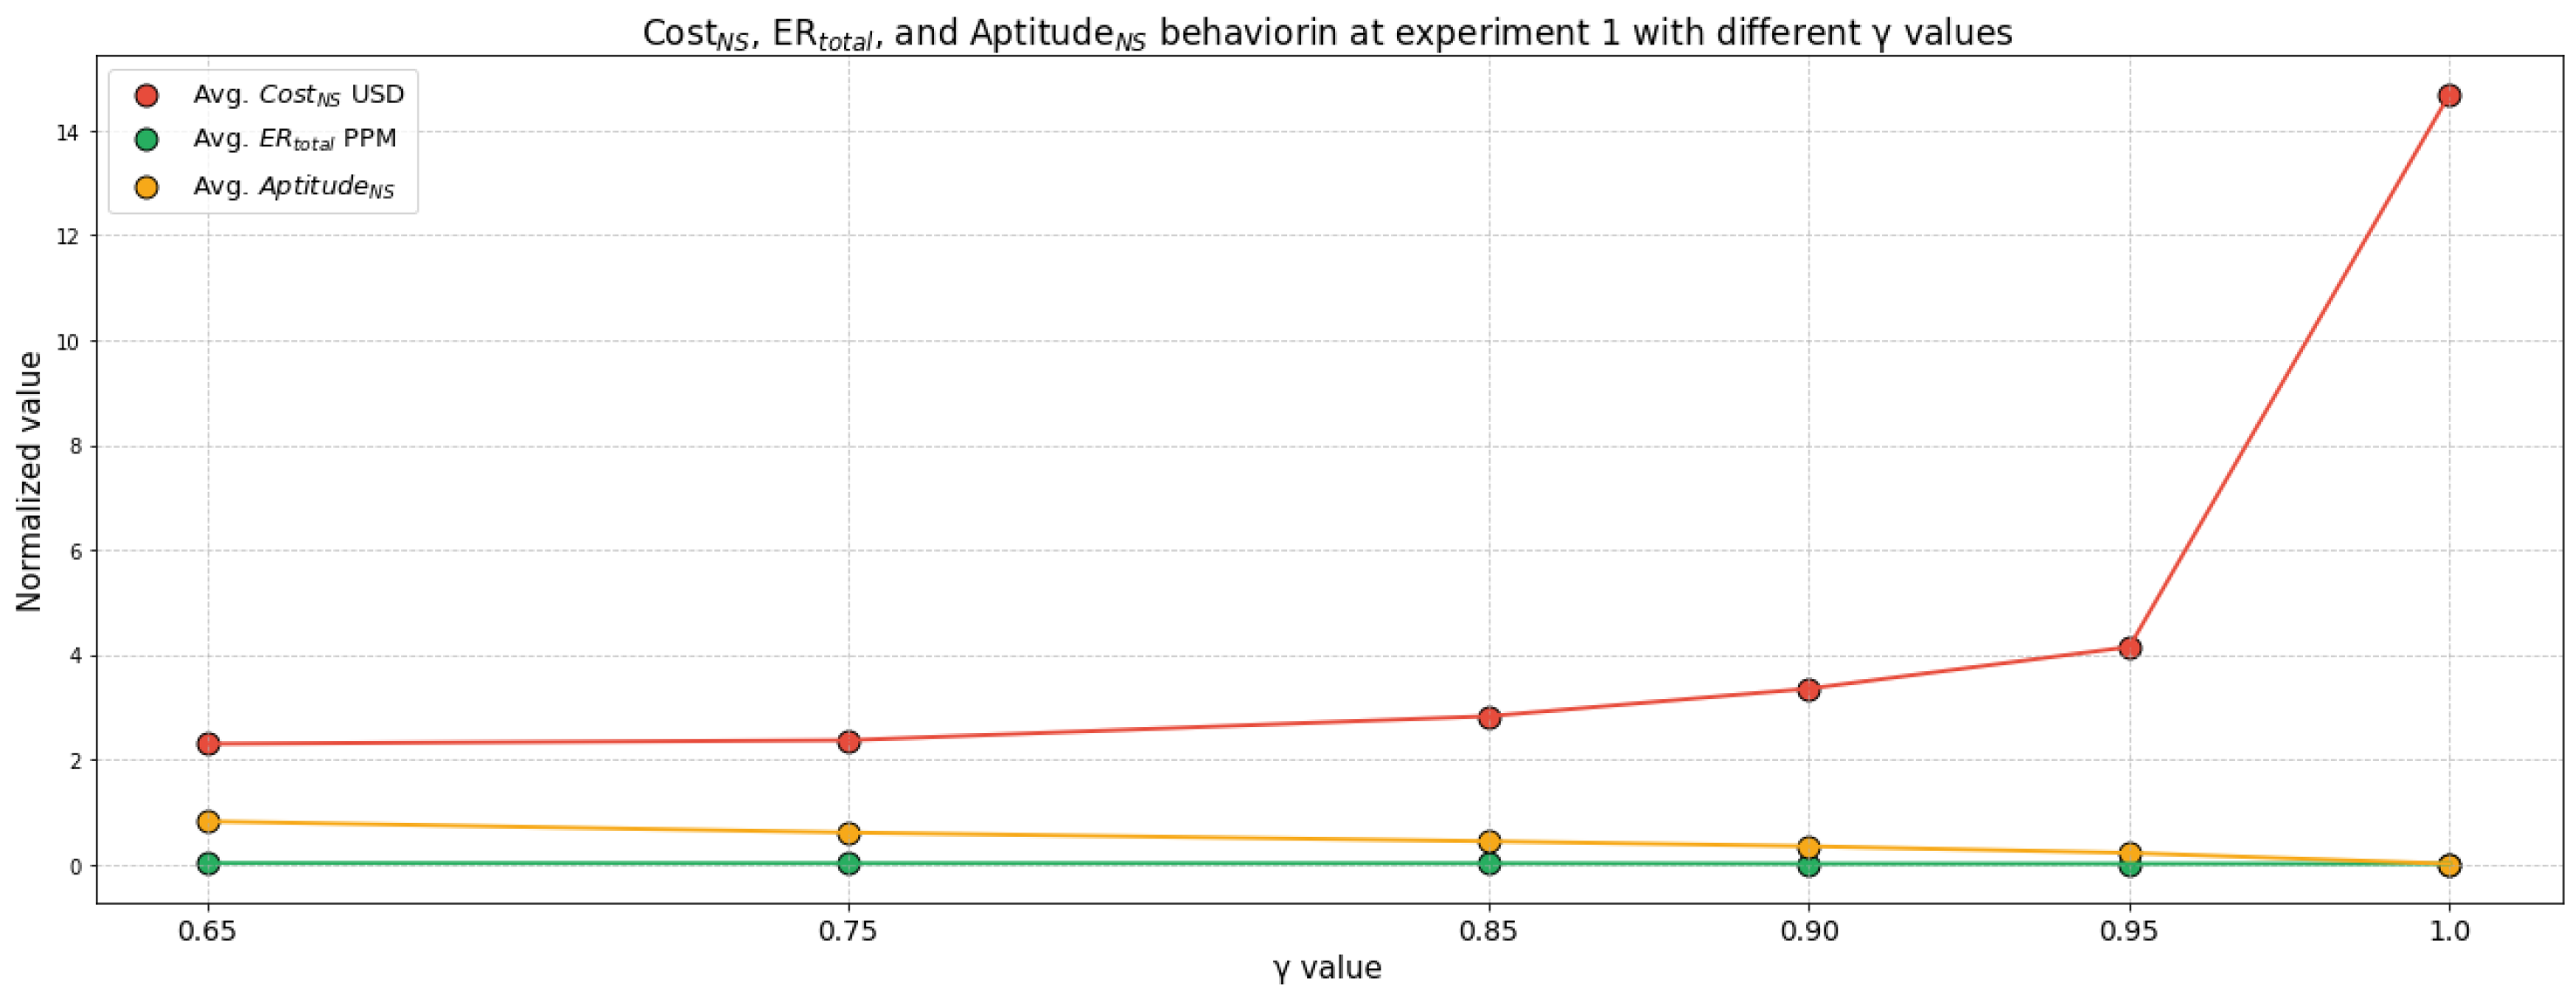
Figure 3 illustrates the behavior of the weighted averages of , , and of the NS as a function of the different values used in the ten runs of the FNSUSA for the first experimental configuration.
Figure 3.
Behavior of , , and parameters with different values in experiment 1.
The behavior of the values in the graph shows the sensitivity of the algorithm to the trade-off between Nutrient and total , , demonstrating how increases in decrease at the expense of .
5.2. Results Generated by FNSUSA in Configuration Targets 2
The second experimental configuration incorporates five chemical elements, Mg, S, and Ca, thus completing the six essential macronutrients required for optimal crop development. Two additional micronutrients, Fe and Zn, are also added, with FNSUSA finding it particularly challenging to achieve the target concentration of 0.5 PPM for Zn due to the low doses required, which make the formulation more complex to generate than the previous configuration.
Table 8 presents the results obtained in the ten runs of the FNSUSA corresponding to the second experimental configuration, highlighting in yellow the best NS based on the lowest value of .
Table 8.
Results generated by FNSUSA for experiment 2 with different values.
Table 9 shows the statistical data from the 60 FNSUSA runs generated with the results from Table 8 for the second experimental configuration, showing small standard deviation values, which demonstrates the repeatability of the FNSUSA.
Table 9.
Statistics for the results in Table 8.
Table 10 contains the quantitative data for the PPMs contained in the NS and their relative error from the best NS formulated using FNSUSA from Table 8.
Table 10.
Comparison of the best solutions in experimental configuration 2 with different values.
Figure 4 shows the quantities expressed in grams of each fertilizer in Table 2 required to formulate the best NS by applying FNSUSA from the second experimental configuration.
Figure 4.
Distribution of the weight for each fertilizer available in Table 2 for the best NS generated for the second experimental configuration.
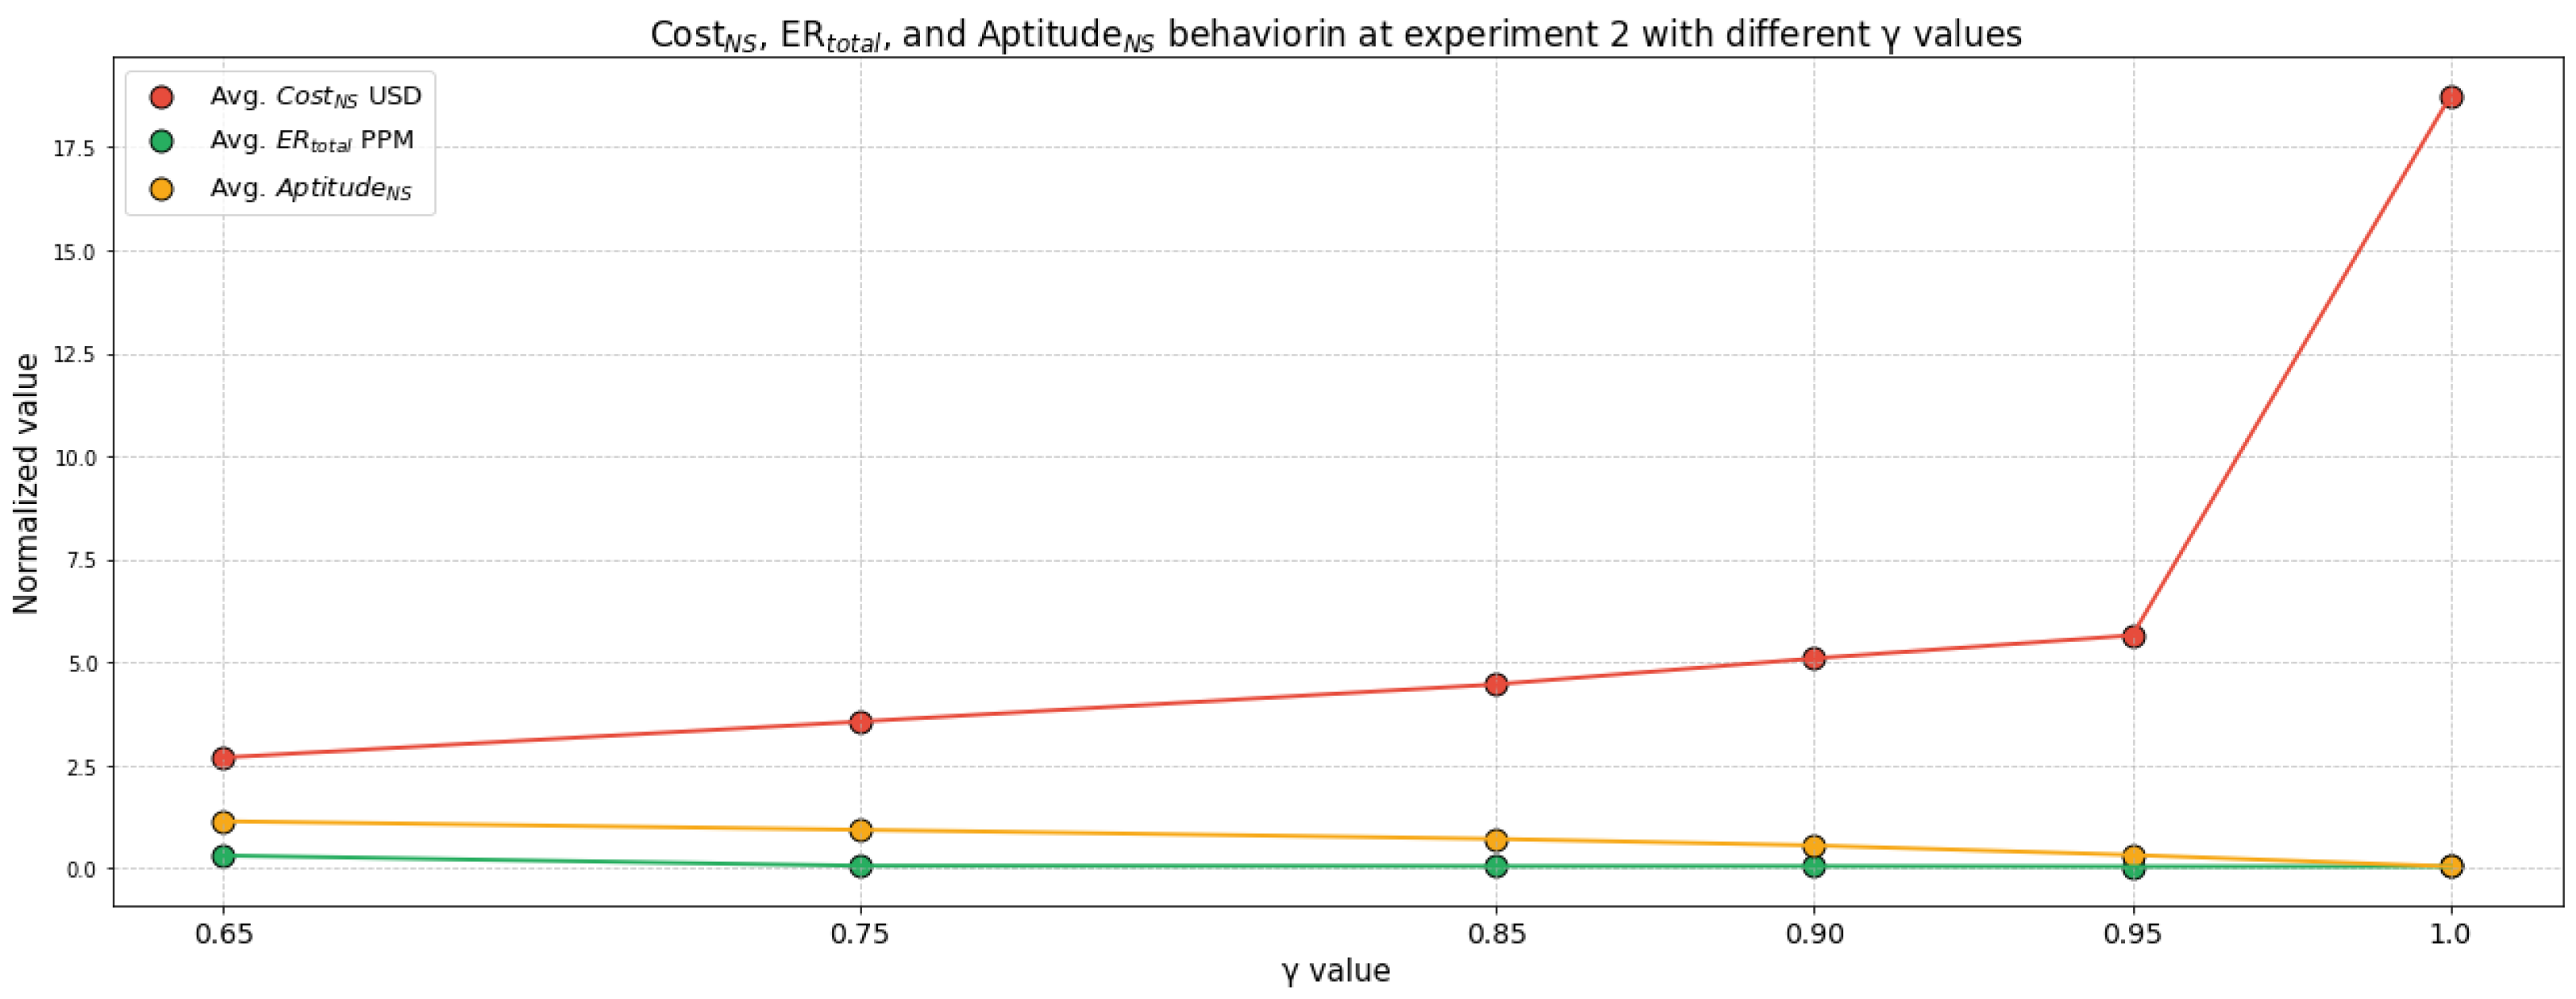
Figure 5 shows that decreases sharply as increases from to . This indicates that low values prioritize the balance between both objectives, while high values favor exclusively the minimization of , shows an inverse trend in relation to . This behavior confirms that maximizing in the formulation of target concentrations in PPM leads to an increase in the cost of NS.
Figure 5.
Behavior of , , and parameters with different values in experiment 2.
5.3. Results Generated by FNSUSA in Configuration Targets 3
The third experimental configuration incorporates the micronutrients Cl, B, Cu, Mn, Mo, and Ni, completing the 15 nutrients required by crops. This configuration highlights the low target concentrations of Mo and Ni, set at PPM in both cases, which pose an additional challenge for FNSUSA due to the need for extremely precise dosing to avoid both deficiencies and potential toxicity. The last configuration is the most difficult, as it requires very small PPM quantities to be achieved.
Table 11 presents the numerical values for , , and obtained in the ten runs of the FNSUSA algorithm for the third experimental configuration, which comprises 15 Nutrient chemical elements. These results correspond to the different weightings of the parameter; the best result obtained is highlighted in yellow, determined by the lowest value of .
Table 11.
Results generated by FNSUSA for experiment 3 with different gamma values.
Finally, Table 12 shows similar standard deviation behavior, demonstrating the repeatability of the results generated by FNSUSA.
Table 12.
Statistics for the results in Table 11.
Table 13 contains the quantitative data for the PPMs contained in the NS and their relative error from the best NS formulated using FNSUSA from Table 11.
Table 13.
Comparison of the best solutions in experimental configuration 3 with different values.
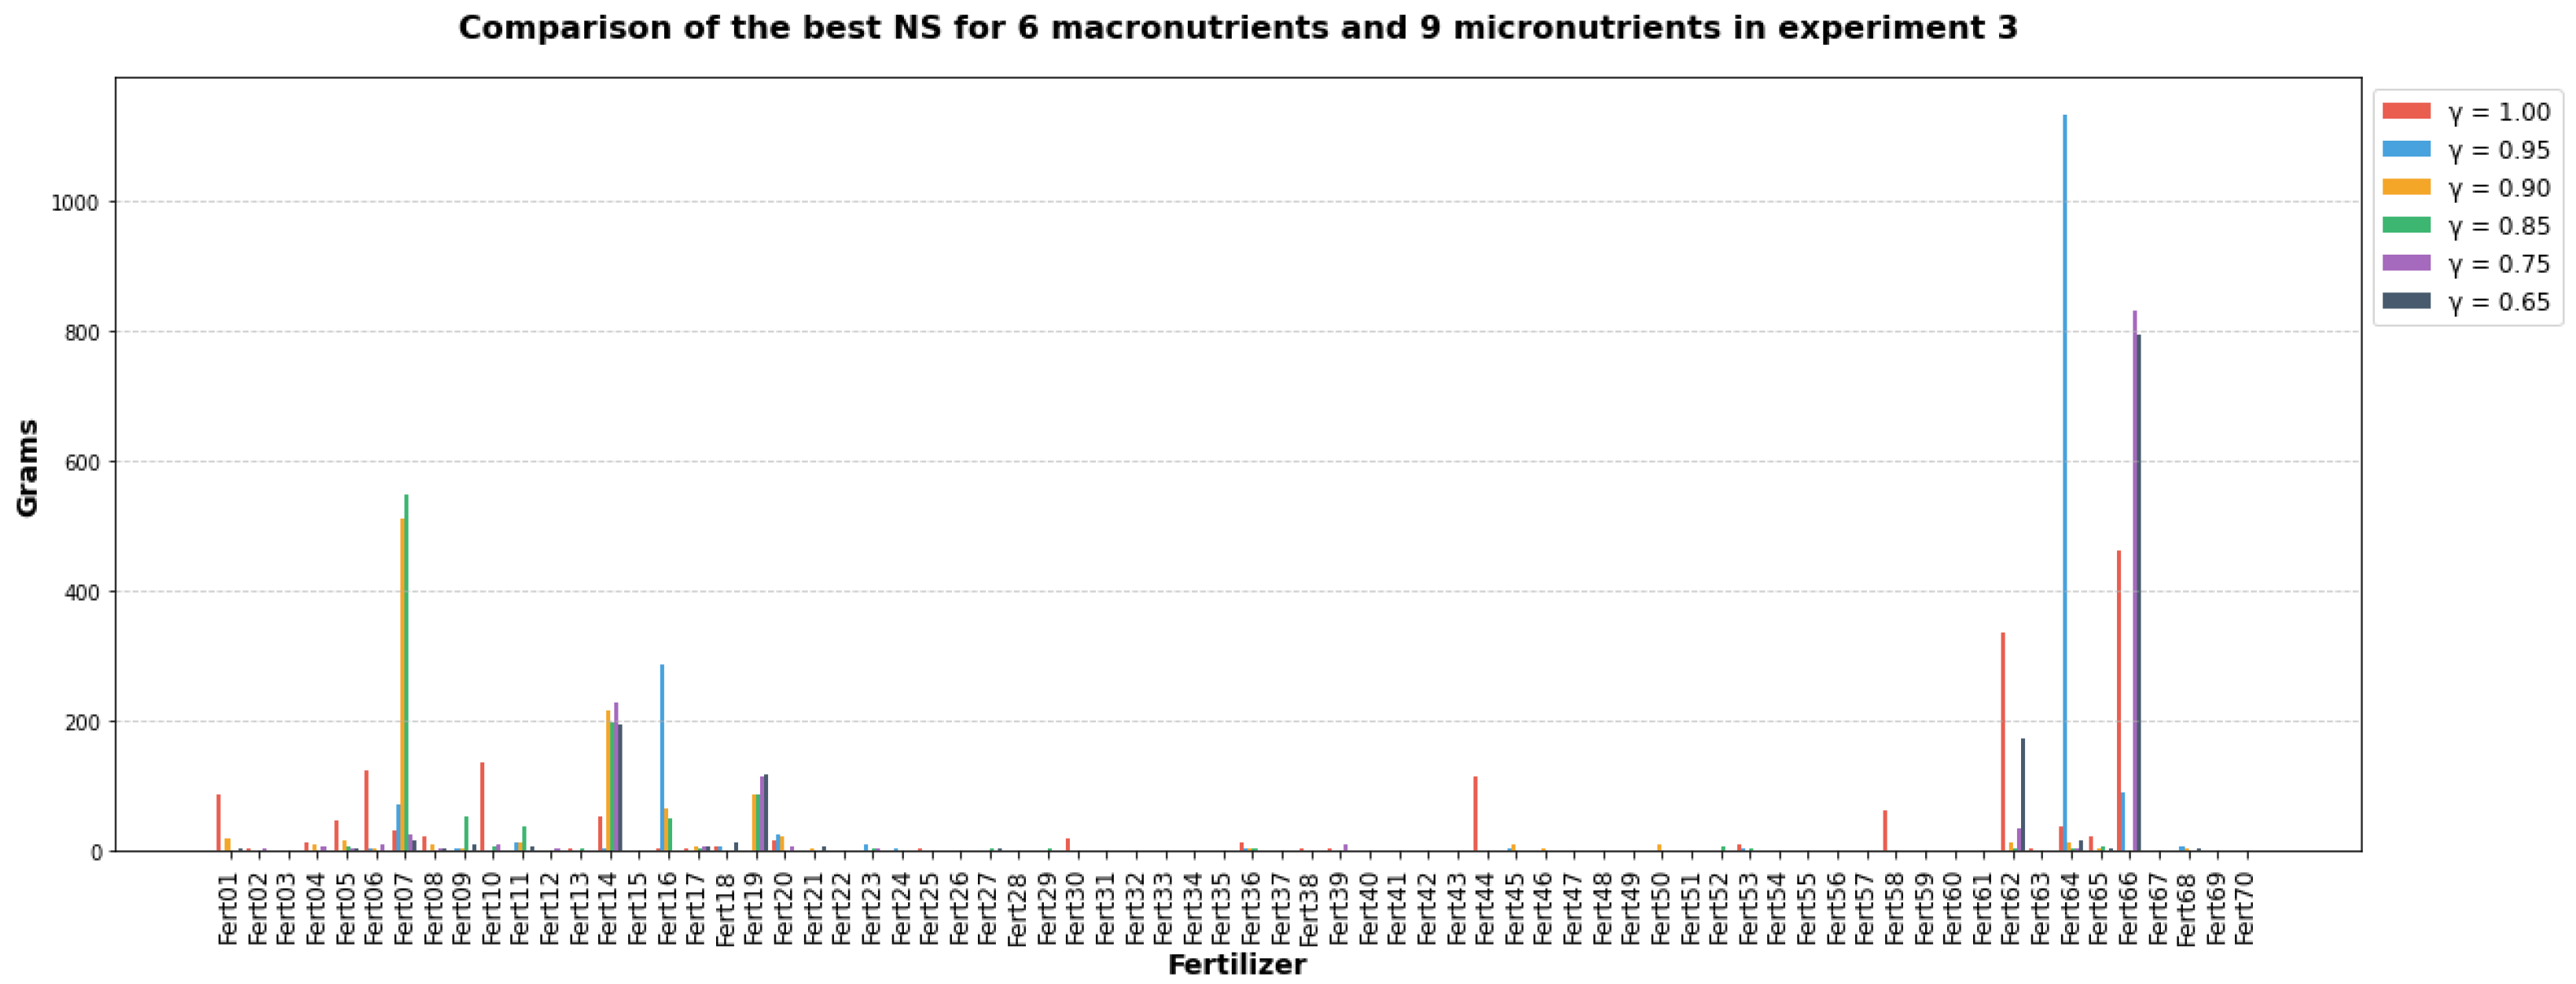
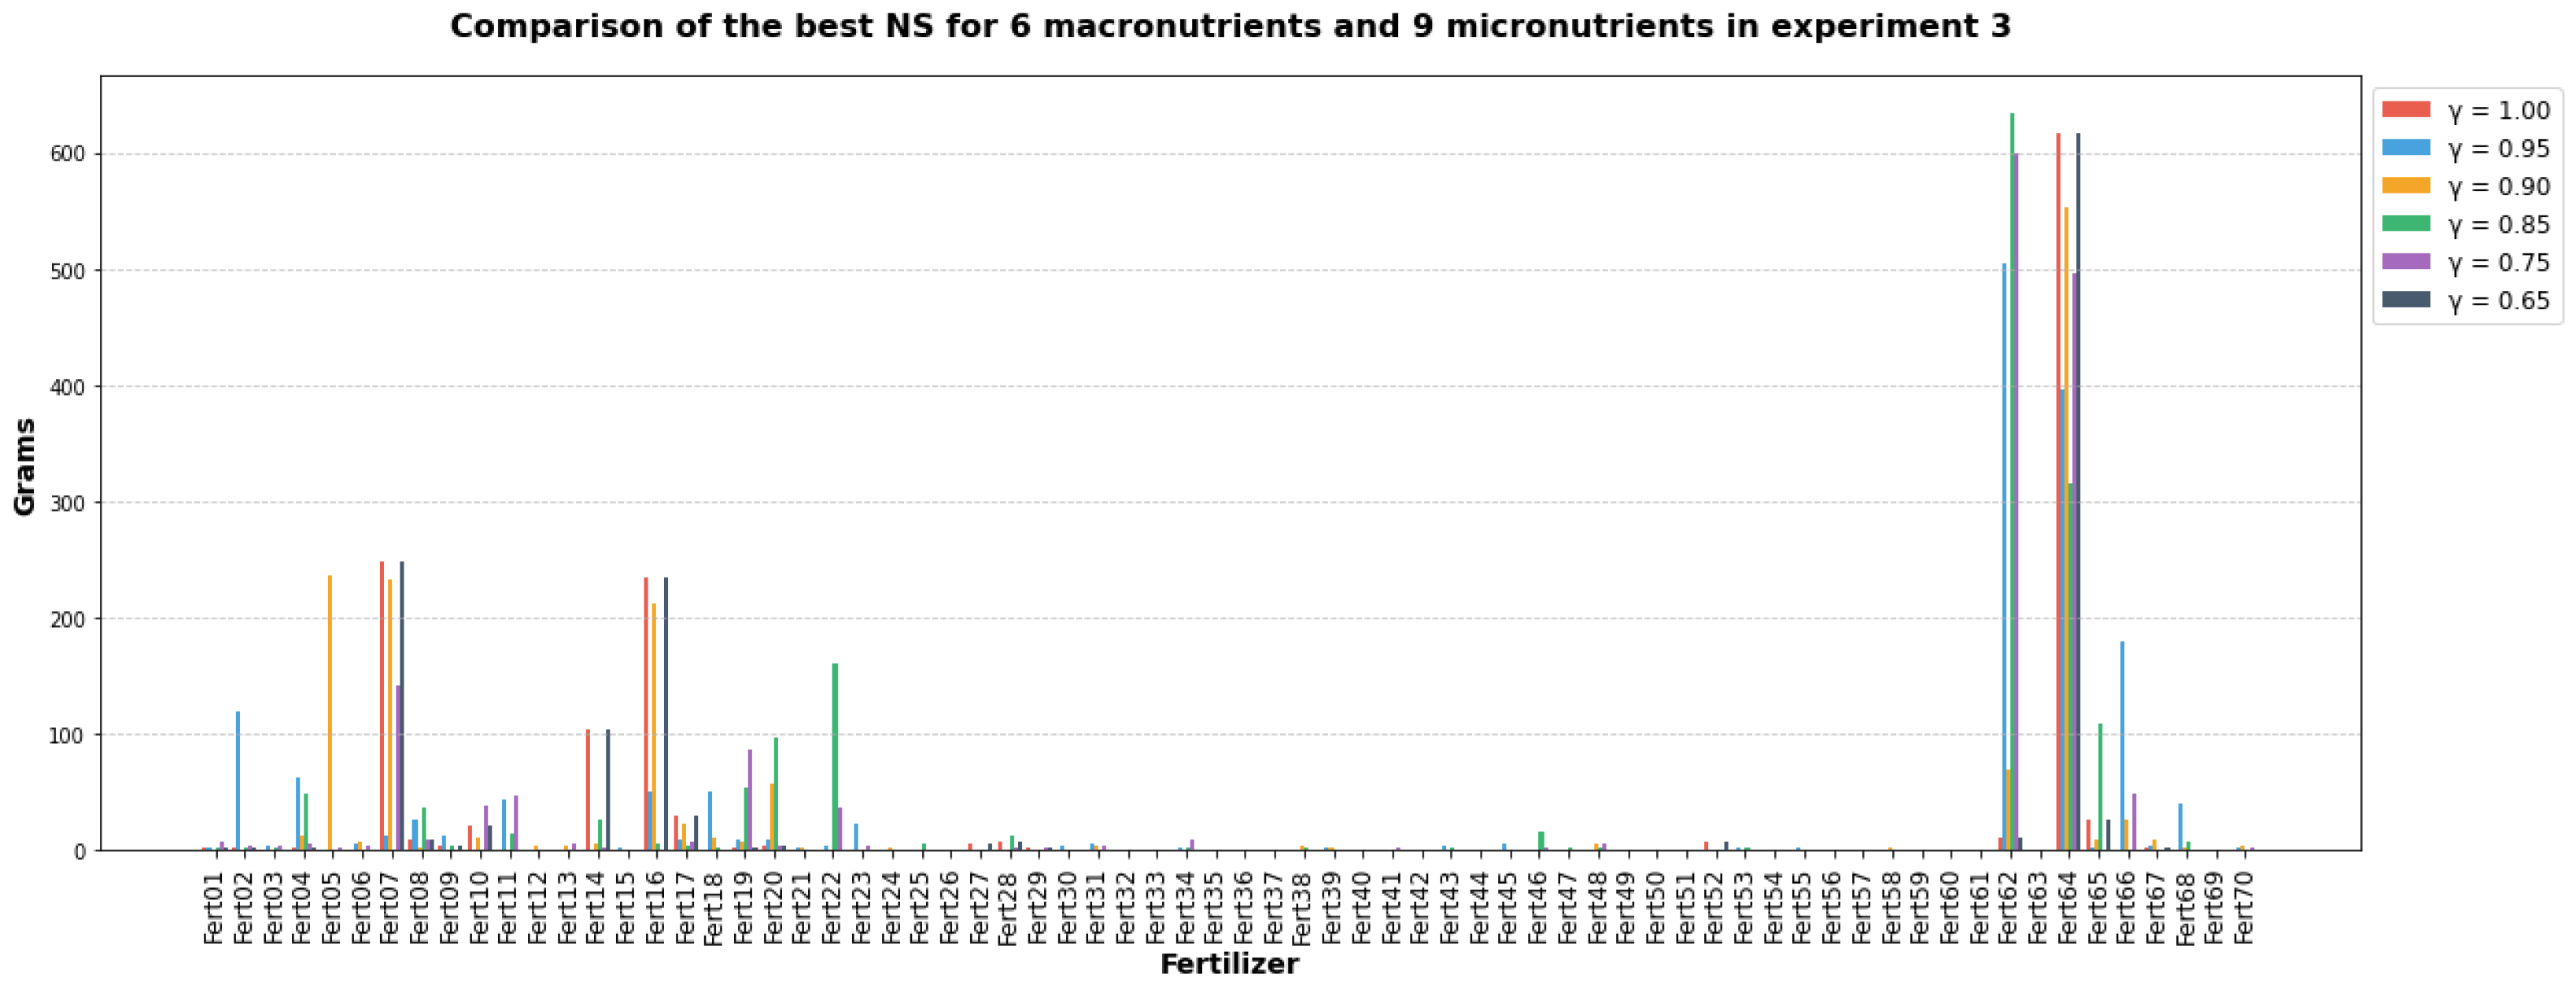
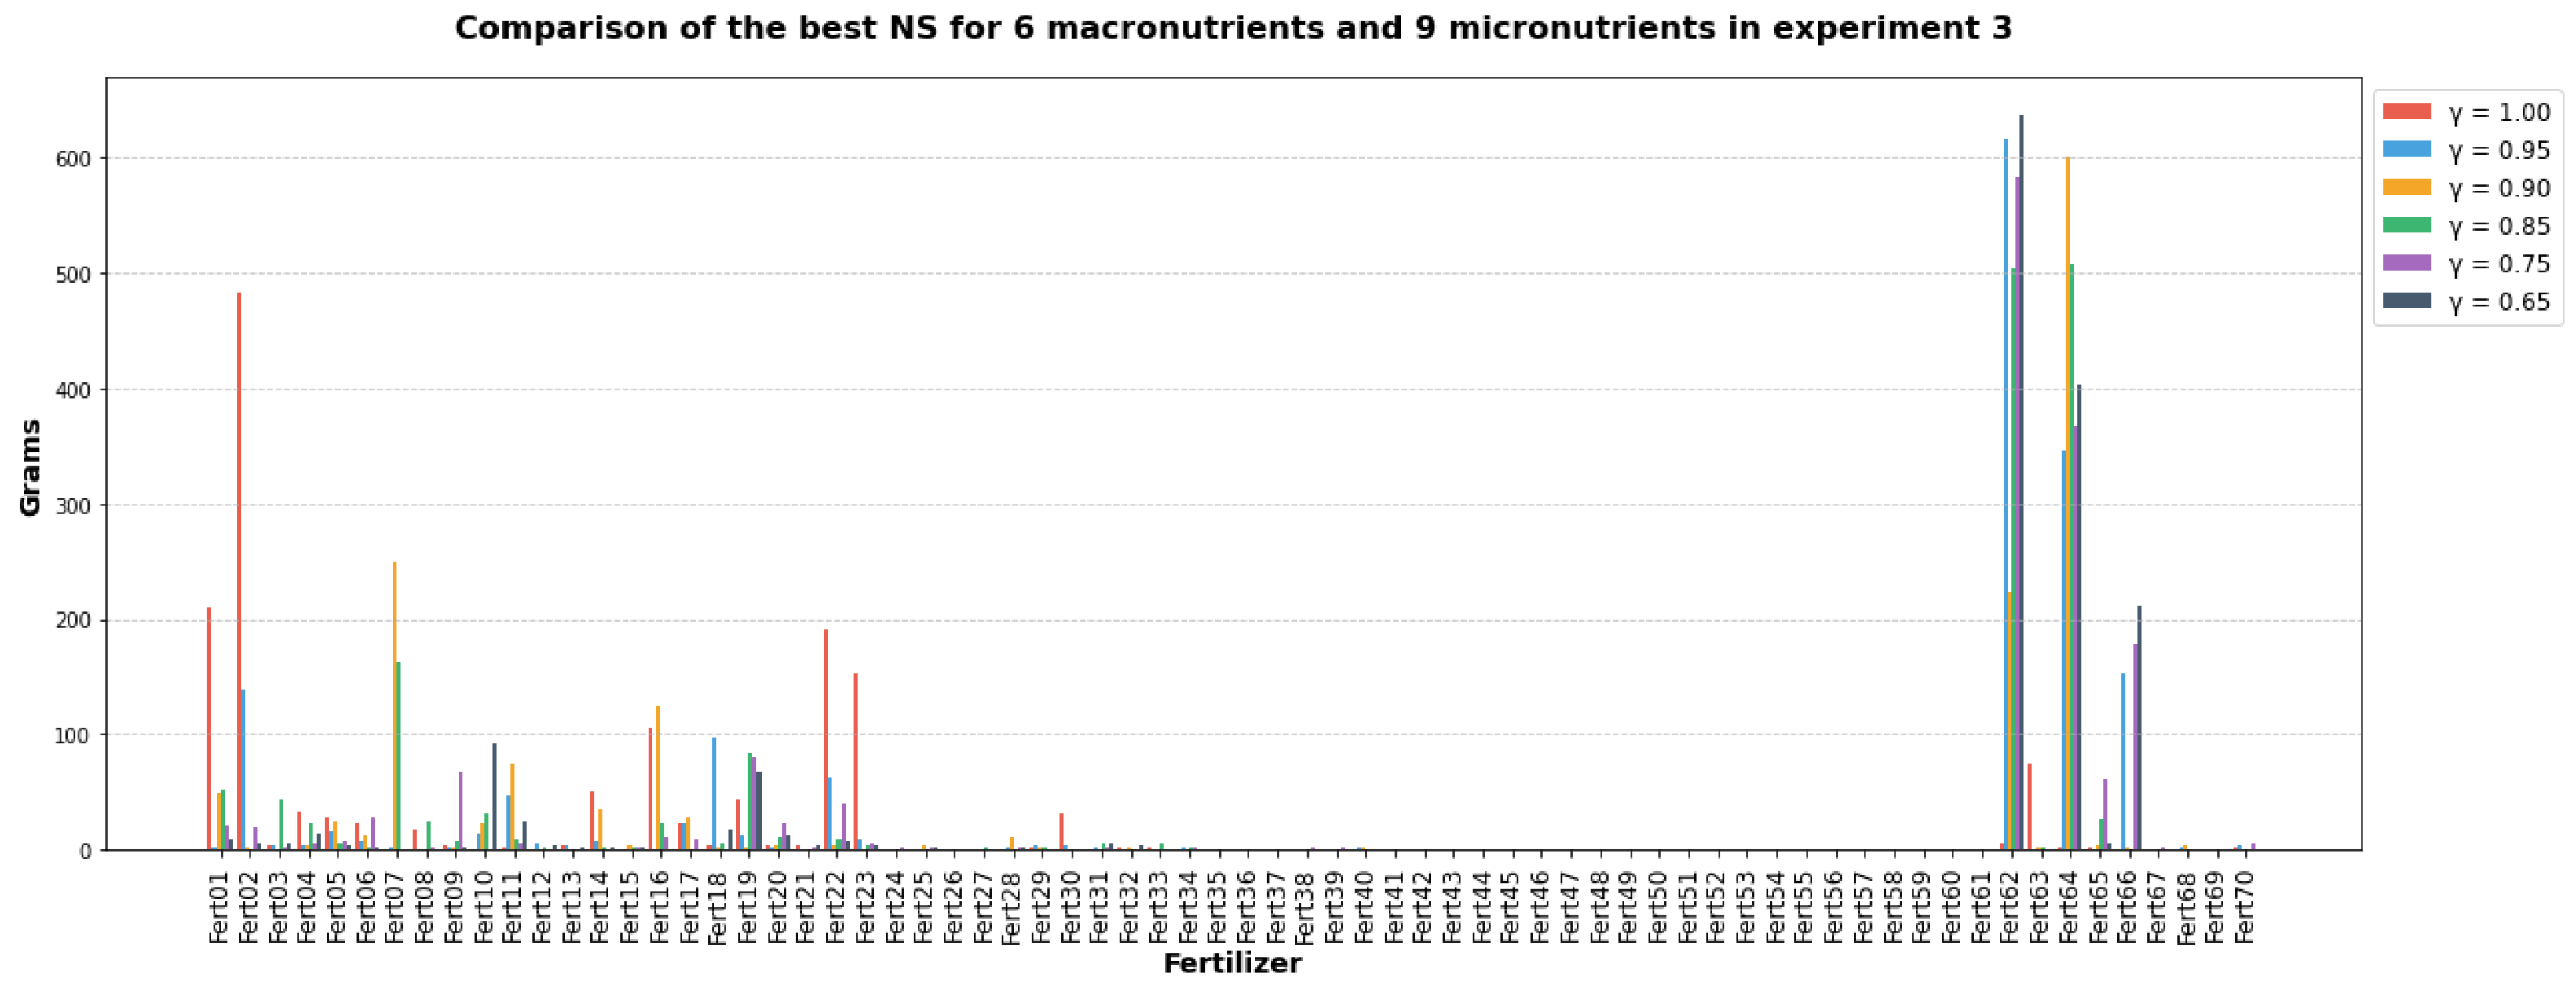
Figure 6 shows the quantities expressed in grams of each fertilizer in Table 2 required to formulate the best NS by applying FNSUSA from the third experimental configuration.
Figure 6.
Distribution of the weight for each fertilizer available in Table 2 for the best NS generated for the third experimental configuration.
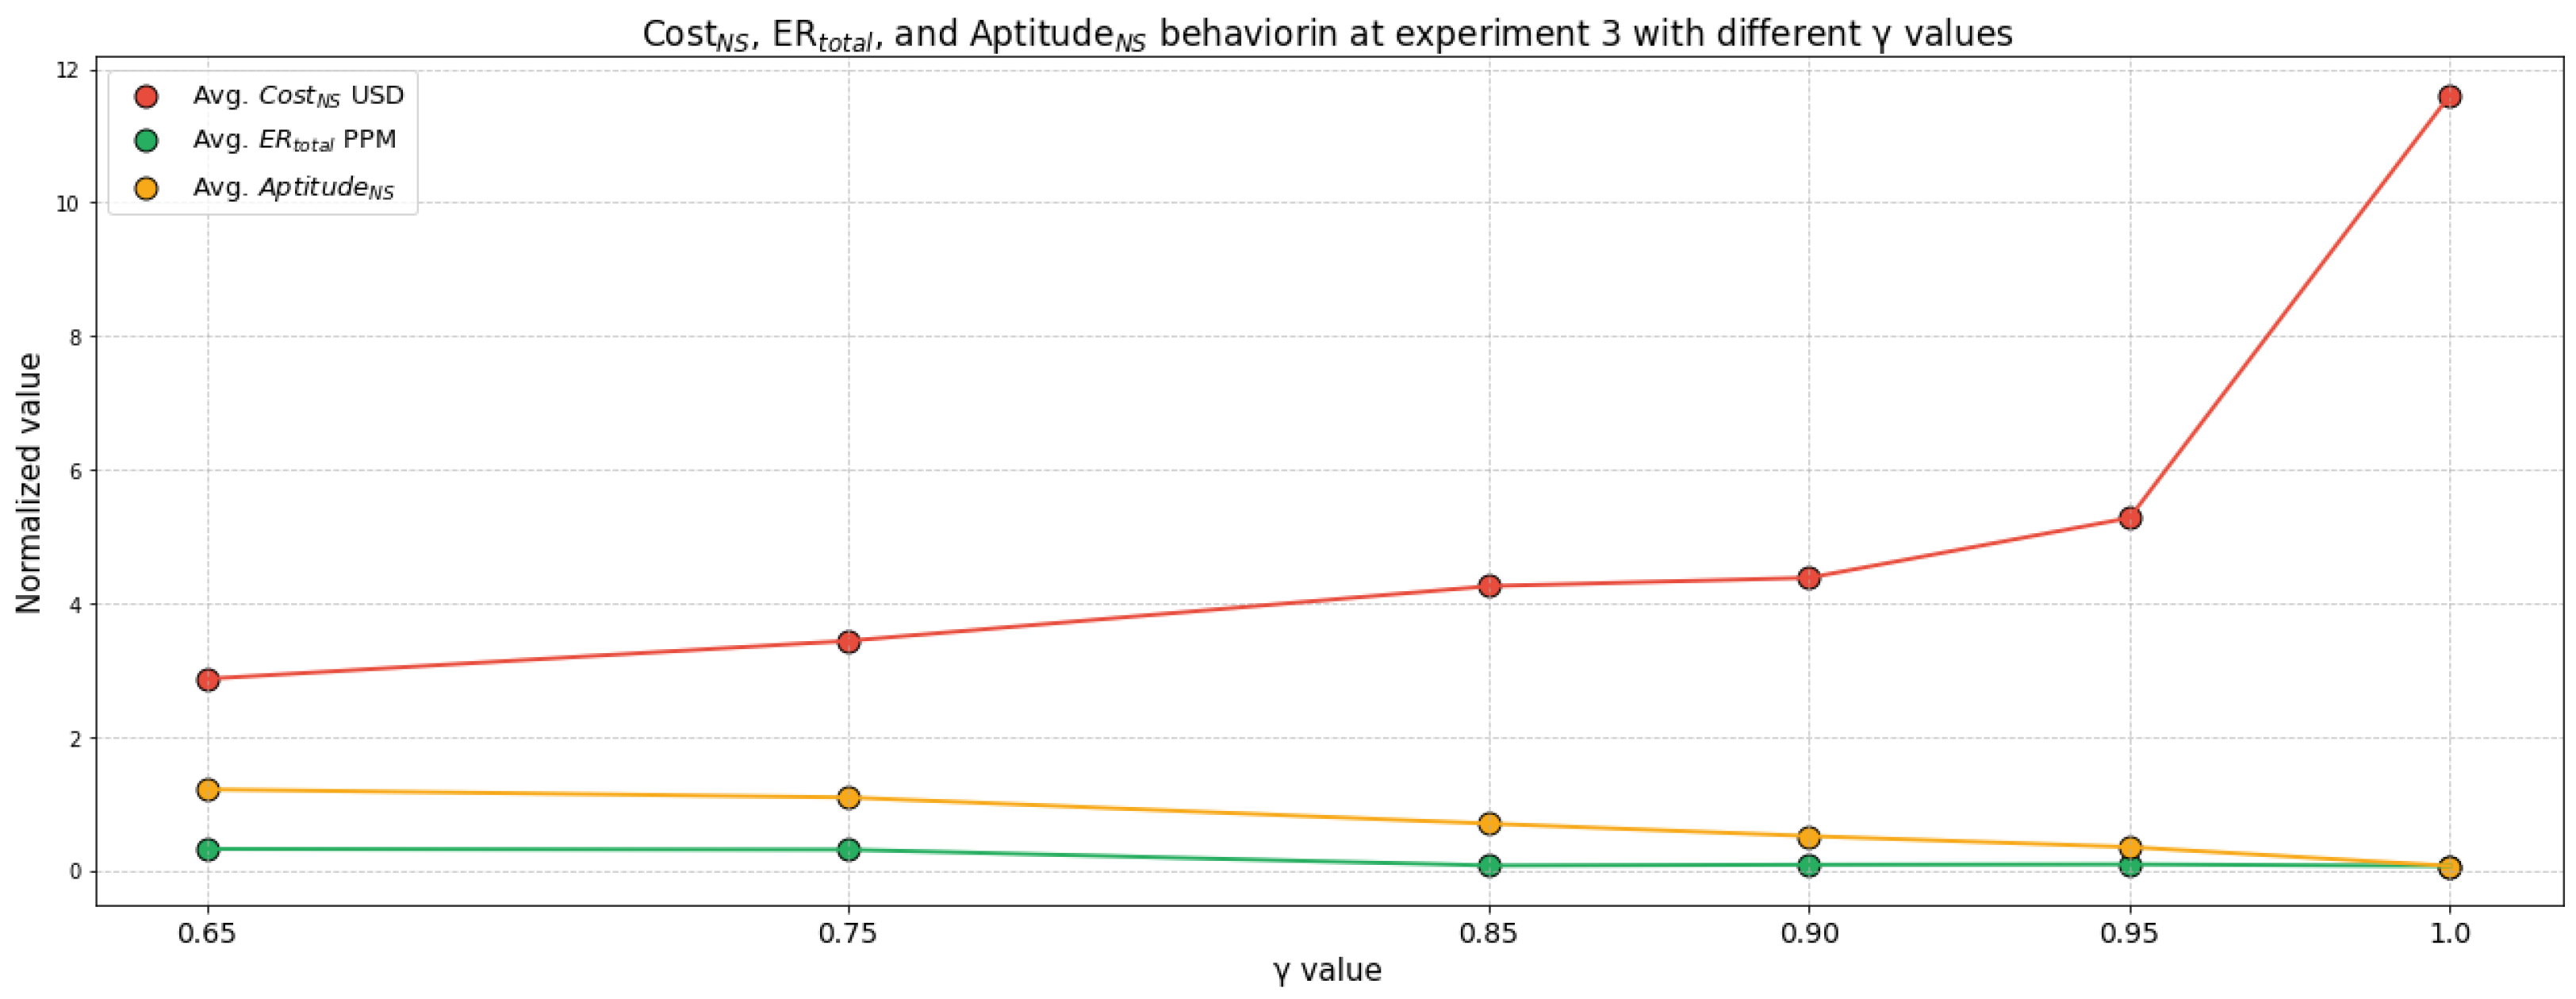
Figure 7 shows a similar behavior to the previous ones in relation to the cost and accuracy values that are weighted in the suitability of the NS. Low gamma values favor lower-cost solutions, accepting slight increases in the relative error of the target concentrations in PPM for macronutrients and micronutrients. In contrast, high gamma values prioritize reducing error in the formulation of the NS, which improves accuracy in meeting Nutrient objectives but increases the cost of the NS.
Figure 7.
Behavior of cost, accuracy, and aptitude parameters with different values in experiment 3.
6. Conclusions
The FNSUSA algorithm efficiently optimizes fertilizer quantities to achieve target PPM concentrations of macronutrients and micronutrients in hydroponic crops. In the three experimental configurations (5, 10, and 15 nutrients), the average relative errors in ten runs with are and respectively, demonstrating accuracy and revealing that complexity increases with the number of nutrients. The accuracy of FNSUSA in calculating fertilizer quantities for low PPM concentrations of micronutrients is noteworthy, especially in the third configuration, where it achieves minimal relative errors for Mo and Ni, both with targets of PPM. Regarding cost, using in the weighting prioritizes accuracy over cost, generating expensive NS with averages of USD 14.70, USD 18.75, and USD 11.61 across the three experimental configurations.
The use of values significantly and consistently minimizes the cost of NS. In the first configuration with 5 nutrients, the average cost of 10 runs decreases from USD 14.70 with to USD 2.30 with . The second configuration with 10 nutrients, from USD 18.75 to USD 2.69, with the same values. Finally, in the third configuration with 15 target nutrients, the cost ranges from USD 11.61 to USD 2.87.
The analysis of weighting with values significantly reduces the cost of NS without significantly increasing the absolute relative error in the target PPM concentrations of nutrients in the three experimental configurations. It is inferred that the most appropriate value for is . The value assigned to the factor helps farmers decide how much they are willing to sacrifice in accuracy in the NS relative to cost, depending on crop conditions.
7. Future Work
One aspect not explored in the reported results is the toxicity of the fertilizers used in the NS formulation. This will be addressed in future work by weighing toxicity against the cost and accuracy of the PPM concentrations for each nutrient. Another aspect to explore in future work, when adding the toxicity factor, is the normalization of the three variables to be balanced in order to avoid bias in the scale. An important aspect is the integration of the presented algorithm with real-time monitoring, which will enable more precise fertilization processes.
Author Contributions
Conceptualization, J.P.G.I. and F.J.C.d.l.R.; methodology, J.P.G.I. and F.J.C.d.l.R.; software, J.P.G.I. and A.J.R.R.; validation, J.P.G.I. and F.J.C.d.l.R.; formal analysis, J.P.G.I. and F.J.C.d.l.R.; investigation, J.P.G.I. and A.J.R.R.; writing—original draft preparation, J.P.G.I. and F.J.C.d.l.R.; writing—review and editing, J.P.G.I. and F.J.C.d.l.R.; supervision, F.J.C.d.l.R. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by Tecnológico Nacional de México, Campus Zamora and by Secretaría de Ciencias, Humanidades, Tecnología e Innovación en Becas Nacionales grants.
Data Availability Statement
The data supporting the conclusions of this article will be made available by the authors on request.
Acknowledgments
It is important to thank the Institutions that made the development of this work possible by allocating resources of different kinds to carry it out. Secretaria de Ciencias, Humanidades, Tecnología e Innovación (SECIHTI), Tecnológico Nacional de México (TecNM), Instituto Tecnológico de Estudios Superiores de Zamora (ITESZ), and Centro de Investigaciones en Óptica A.C. (CIO).
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Awasthi, Y. Press “A” for Artificial Intelligence in Agriculture: A Review. Int. J. Inform. Vis. 2020, 4, 112–116. [Google Scholar] [CrossRef] [Scilit]
- Ray, P.P. Internet of things for smart agriculture: Technologies, practices and future direction. J. Ambient. Intell. Smart Environ. 2017, 9, 395–420. [Google Scholar] [CrossRef] [Scilit]
- FAO. Our Approach|Food Systems|Food and Agriculture Organization of the United Nations. 2023. Available online: http://www.fao.org/food-systems/our-approach/en/ (accessed on 1 December 2024).
- Brown, P.D.; Cochrane, T.A.; Krom, T.D. Optimal on-farm irrigation scheduling with a seasonal water limit using simulated annealing. Agric. Water Manag. 2010, 97, 892–900. [Google Scholar] [CrossRef] [Scilit]
- Dong, Y.; Zhao, C.; Yang, G.; Chen, L.; Wang, J.; Feng, H. Integrating a very fast simulated annealing optimization algorithm for crop leaf area index variational assimilation. Math. Comput. Model. 2013, 58, 877–885. [Google Scholar] [CrossRef] [Scilit]
- Bai, Y.; Gao, J. Optimization of the nitrogen fertilizer schedule of maize under drip irrigation in Jilin, China, based on DSSAT and GA. Agric. Water Manag. 2021, 244, 106555. [Google Scholar] [CrossRef] [Scilit]
- Gebbers, R.; Adamchuk, V.I. Precision agriculture and food security. Science 2010, 327, 828–831. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Pierce, F.J.; Nowak, P. Aspects of precision agriculture. Adv. Agron. 1999, 67, 1–68. [Google Scholar]
- Patrício, D.I.; Rieder, R. Computer vision and artificial intelligence in precision agriculture for grain crops: A systematic review. Comput. Electron. Agric. 2018, 153, 69–81. [Google Scholar] [CrossRef] [Scilit]
- Bertsimas, D.; Tsitsiklis, J. Simulated Annealing. Stat. Sci. 1993, 8, 409–435. [Google Scholar] [CrossRef] [Scilit]
- Nanni, L.; Maguolo, G.; Pancino, F. Insect pest image detection and recognition based on bio-inspired methods. Ecol. Inform. 2020, 57, 101089. [Google Scholar] [CrossRef] [Scilit]
- Mundada, R.G.M. Detection and Classification of Pests in Greenhouse Using Image Processing. IOSR J. Electron. Commun. Eng. 2013, 5, 57–63. [Google Scholar] [CrossRef] [Scilit]
- Fan, P.; Lang, G.; Yan, B.; Lei, X.; Guo, P.; Liu, Z.; Yang, F. A Method of Segmenting Apples Based on Gray-Centered RGB Color Space. Remote Sens. 2021, 13, 1211. [Google Scholar] [CrossRef] [Scilit]
- Ni, X.; Li, C.; Jiang, H.; Takeda, F. Deep learning image segmentation and extraction of blueberry fruit traits associated with harvestability and yield. Hortic. Res. 2020, 7, 110. [Google Scholar] [CrossRef] [Scilit]
- Guerra Ibarra, J.P.; Cuevas de la Rosa, F. Optimization of Color Dominance Factor by Greedy Algorithm for Leaves and Fruit Segmentation of Tomato Plants. In Proceedings of the Lecture Notes in Computer Science (Including Subseries Lecture Notes in Artificial Intelligence and Lecture Notes in Bioinformatics); Mezura-Montes, E., Acosta-Mesa, H.G., Carrasco-Ochoa, J.A., Martínez-Trinidad, J.F., Olvera-López, J.A., Eds.; Springer: Cham, Switzerland, 2024; Volume 14755 LNCS, pp. 200–209. [Google Scholar] [CrossRef] [Scilit]
- Kuo, S.F.; Merkley, G.P.; Liu, C.W. Decision support for irrigation project planning using a genetic algorithm. Agric. Water Manag. 2000, 45, 243–266. [Google Scholar] [CrossRef] [Scilit]
- Cropper, W.P.; Comerford, N.B. Optimizing simulated fertilizer additions using a genetic algorithm with a nutrient uptake model. Ecol. Model. 2005, 185, 271–281. [Google Scholar] [CrossRef] [Scilit]
- Lu, J.; Yang, T.; Su, X.; Qi, H.; Yao, X.; Cheng, T.; Zhu, Y.; Cao, W.; Tian, Y. Monitoring leaf potassium content using hyperspectral vegetation indices in rice leaves. Precis. Agric. 2020, 21, 324–348. [Google Scholar] [CrossRef] [Scilit]
- Qi, X.; Zhao, Y.; Huang, Y.; Wang, Y.; Qin, W.; Fu, W.; Guo, Y.; Ye, Y. A novel approach for nitrogen diagnosis of wheat canopies digital images by mobile phones based on histogram. Sci. Rep. 2021, 11, 13012. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Li, M.; Li, J.; Mao, H.; Wu, Y. Diagnosis and detection of phosphorus nutrition level for Solanum lycopersicum based on electrical impedance spectroscopy. Biosyst. Eng. 2016, 143, 108–118. [Google Scholar] [CrossRef] [Scilit]
- Sun, Y.; Tong, C.; He, S.; Wang, K.; Chen, L. Identification of Nitrogen, Phosphorus, and Potassium Deficiencies Based on Temporal Dynamics of Leaf Morphology and Color. Sustainability 2018, 10, 762. [Google Scholar] [CrossRef] [Scilit]
- Tran, T.T.; Choi, J.W.; Le, T.T.H.; Kim, J.W. A comparative study of deep CNN in forecasting and classifying the macronutrient deficiencies on development of tomato plant. Appl. Sci. 2019, 9, 1601. [Google Scholar] [CrossRef] [Scilit]
- Xu, X.; He, P.; Yang, F.; Ma, J.; Pampolino, M.F.; Johnston, A.M.; Zhou, W. Methodology of fertilizer recommendation based on yield response and agronomic efficiency for rice in China. Field Crop. Res. 2017, 206, 33–42. [Google Scholar] [CrossRef] [Scilit]
- Ahmad, I.; Wajid, S.A.; Ahmad, A.; Cheema, M.J.M.; Judge, J. Optimizing irrigation and nitrogen requirements for maize through empirical modeling in semi-arid environment. Environ. Sci. Pollut. Res. 2019, 26, 1227–1237. [Google Scholar] [CrossRef] [Scilit]
- Ahmed, U.; Lin, J.C.W.; Srivastava, G.; Djenouri, Y. A nutrient recommendation system for soil fertilization based on evolutionary computation. Comput. Electron. Agric. 2021, 189, 106407. [Google Scholar] [CrossRef] [Scilit]
- Chen, C.; Wang, X.; Chen, H.; Wu, C.; Mafarja, M.; Turabieh, H. Towards precision fertilization: Multi-strategy grey wolf optimizer based model evaluation and yield estimation. Electronics 2021, 10, 2183. [Google Scholar] [CrossRef] [Scilit]
- Mengel, K.; Kirkby, E. Principles of Vegetable Nutrition; Springer: Dordrecht, The Netherlands, 1978; Volume 15B,A. [Google Scholar]
- Dimkpa, C.O.; Bindraban, P.S. Fortification of micronutrients for efficient agronomic production: A review. Agron. Sustain. Dev. 2016, 36, 7. [Google Scholar] [CrossRef] [Scilit]
- Resh, H.M. Hydroponic Food Production: A Definitive Guidebook for the Advanced Home Gardener and the Commercial Hydroponic Grower. In Hydroponic Food Production; CRC Press: Boca Raton, FL, USA, 2022. [Google Scholar] [CrossRef] [Scilit]
- Savvas, D.; Gruda, N. Application of soilless culture technologies in the modern greenhouse industry—A review. Eur. J. Hortic. Sci. 2018, 83, 280–293. [Google Scholar] [CrossRef] [Scilit]
- Kirkpatrick, S.; Gelatt, C.D.; Vecchi, M.P. Optimization by simulated annealing. Science 1983, 220, 671–680. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Mahdi, W.; Medjahed, S.A.; Ouali, M. Performance analysis of simulated annealing cooling schedules in the context of dense image matching. Comput. y Sist. 2017, 21, 493–501. [Google Scholar] [CrossRef] [Scilit]
- Cámara de Comercio de Bogotá CCB. Manual Tomate; Cámara de Comercio de Bogotá: Bogotá, Colombia, 2015; pp. 1–56. [Google Scholar]
- Steiner, A.A. A universal method for preparing nutrient solutions of a certain desired composition. Plant Soil 1961, 15, 134–154. [Google Scholar] [CrossRef] [Scilit]
- Sonneveld, C.; Voogt, W. Plant Nutrition of Greenhouse Crops; Springer: Dordrecht, The Netherlands, 2009; pp. 1–431. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.