


Abstract
This paper addresses the problem of low electromagnetic weft insertion acceleration performance of extra-large width automatic looms. Based on single-stage electromagnetic weft insertion and multi-stage intermittent electromagnetic weft insertion, a sectional combined continuous acceleration electromagnetic weft insertion design plan is proposed. First, a new type of weft gripper for electromagnetic weft insertion is designed on the basis of the traditional projectile, and a segmented combined structure optimization design is carried out on the 90 mm single-stage coil. Next, the electromagnetic weft insertion movement model is established to analyze the force and movement speed of the gripper during the movement. The amount of work done by the electromagnetic force of the combined coil determines the exit speed of the weft gripper. Finally, in order to find the best parameters of the combined coil structure to meet the requirements of the launch speed, the steady state and transient performance of the segmented combined continuous acceleration coil are analyzed using Maxwell simulation software. The launch performance of the combined coil with different axial lengths of 45 mm, 30 mm, and 15 mm is compared. The results show that the entire acceleration process is more stable and efficient when the combined coil length is 30 mm, the inner diameter is 18 mm, and the number of turns is 600.
1. Introduction
Industrial fabrics with extra-large width (12 m and above) have overall strength consistency, can enhance the protection of dams, mountains, and coasts, and can be used in fields such as flood resistance and tsunami resistance. High-speed weft insertion is a key prerequisite for the production of extra-large width fabrics. The existing regular size automatic weaving equipment is divided into two types: shuttle weft insertion and shuttleless weft insertion. Compared with the shuttle weft insertion, the shuttleless weft insertion does not need to fly with the weft clamp. It has the advantages of high weft insertion speed and low noise caused by the weft insertion movement. In the case of shuttleless weft insertion, the loom can be divided into: air jet loom, water jet loom, rapier loom, and projectile loom. The first three looms have a width of 1.9 to 4.0 m [1,2,3]. The projectile loom has a wider door width, up to 5.4 m or more [4], but due to the limitation of the torsion shaft structure material, the weft insertion flight length is difficult to reach the requirement of extra-large width. Therefore, realizing the stability, reliability, and high-speed weft insertion of the extra-large width high-speed automatic loom is an urgent problem that needs to be solved in the high-speed weaving equipment of industrial textiles.
In order to meet the needs of different weft insertion, much research has been carried out at home and abroad. For example, in order to reduce the energy consumption of air-jet looms, a new weft insertion method of main nozzle + weft insertion piece is proposed [5], as well as a new three-dimensional cylindrical fabric forming weft insertion method [6], and a magnetoelectric weft insertion device designed for the defects of shuttle looms [7]. In spite of the innovation and improvement of various weft insertion methods, in the weaving of extra-large width industrial textiles, the existing weft insertion methods cannot meet the requirements of long-distance weft insertion.
In recent years, electromagnetic launch technology which has many characteristics such as good controllability, high safety and reliability, high energy utilization, and reusability, has been widely used in missile launches, take-off catapults, and industrial production, and is favored by many industries [8]. In the study of electromagnetic launch weft insertion mechanism, Japan proposed the electromagnetic shuttle insertion scheme of the loom in 1977 [9]. Owlia Emad et al. explored the influence of launcher parameters on projectile velocity [10], and proposed an adaptive neuro-fuzzy system that can quickly calculate the dynamic parameters of the weft insertion process [11]. S.A. Mirjalill proposed a magnetic weft insertion system based on electromagnetic force, and designed and made a weft insertion model [12]. Jan Vincent Jordan introduced a new weft insertion method that combines the advantages of traditional weft insertion methods while avoiding the problem of excessive energy consumption in the past. It is based on the principle of magnetic force to control the delivery of weft yarns [13]. In the literature [14], we found that the launch performance is best when the length of the accelerating coil is the same as the length of the ferromagnetic weft gripper. During the acceleration process in a single coil, the electromagnetic force received by the ferromagnetic weft gripper shows a tendency to increase first and then decrease.
In order to further improve the work done by electromagnetic force, this paper proposes a continuous acceleration electromagnetic weft insertion method. By changing the energization mode of the multi-stage segmented coil, the range of the peak electromagnetic force received by the ferromagnetic weft clamp is extended to realize high-speed weft insertion. This method has the potential to prepare extra-large width fabrics. The organization structure of the article is as follows: the second part introduces the working principle of the continuous acceleration electromagnetic weft insertion system; the third part introduces the structural design of each part of the continuous acceleration electromagnetic weft insertion system; the fourth part verifies the theoretical feasibility of the continuous acceleration electromagnetic weft insertion method through the comparison of theory and simulation; and the fifth part summarizes the whole research work and research results of this article.
2. Working Principle of Continuous Acceleration Electromagnetic Weft Insertion System
2.1. Single-Stage Electromagnetic Weft Insertion
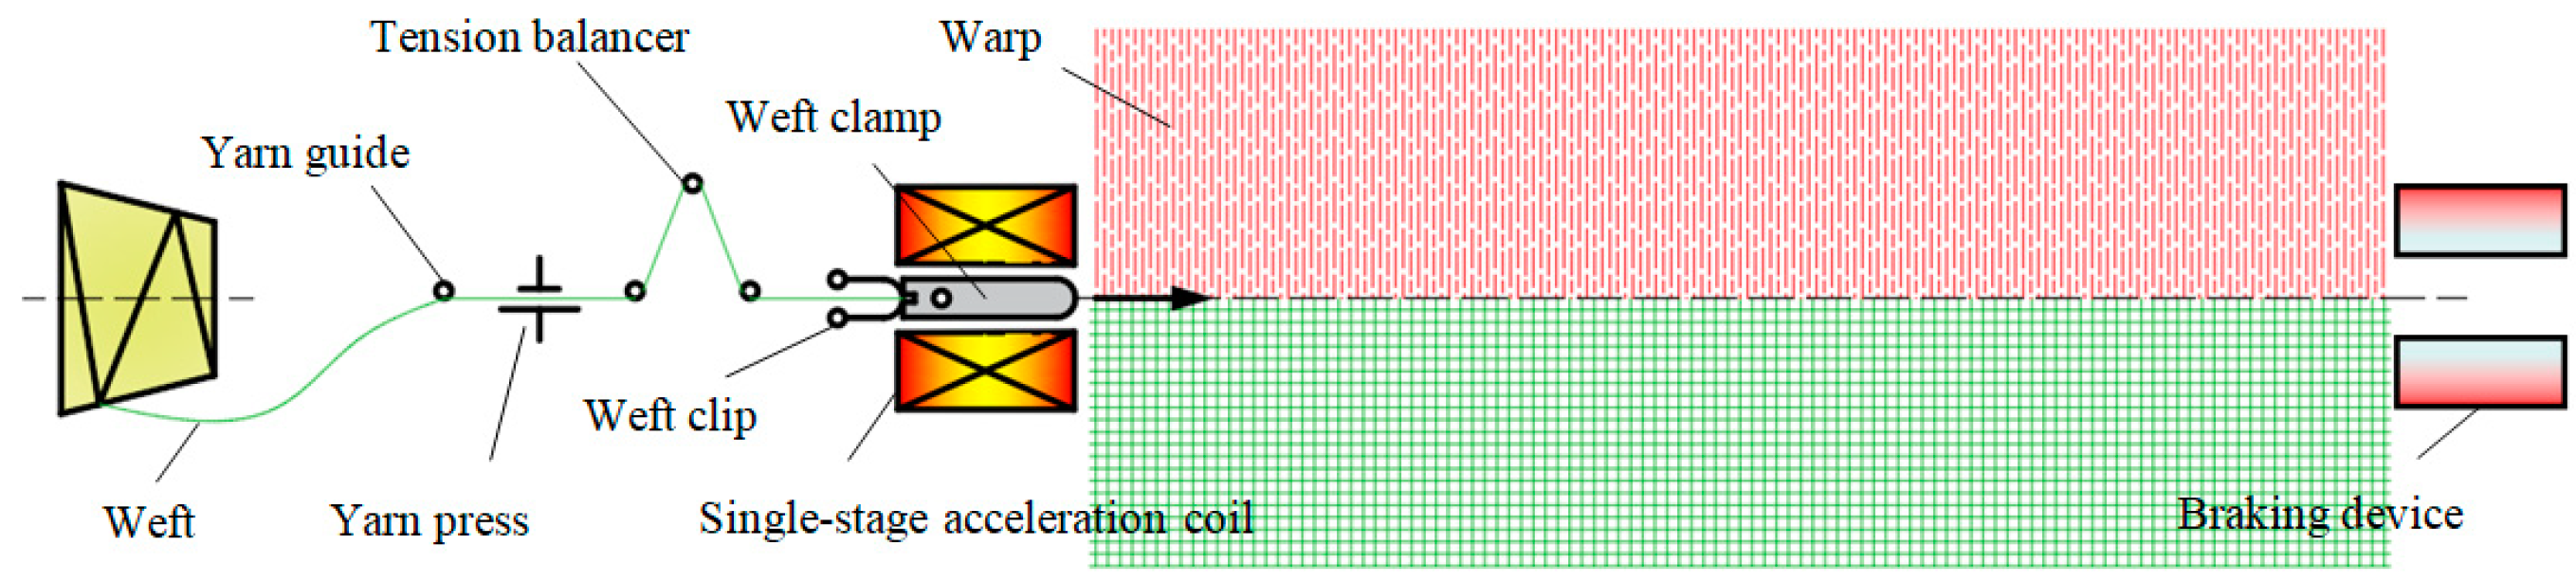
In order to solve the problem of the weft insertion power of the extra-large width loom, the electromagnetic launch method is introduced into the projectile loom to replace the torsion shaft picking type weft insertion method. The principle of single-stage electromagnetic weft insertion is shown in Figure 1. When the gripping device of the weft gripper is gradually opened, the weft delivery gripper holds the weft yarn head and approaches the weft gripper. At the same time, the tension balance bar is located at the highest position to tighten the weft yarn, and then the weft yarn is compressed by the yarn presser. The jaws of the gripping device are closed and hold the weft thread, and the jaws of the weft thread delivery are now open. The weft exchange process is completed. Finally, the single-stage acceleration coil is energized, the yarn presser rises synchronously, and the tension balancer starts to fall. The ferromagnetic weft gripper is ready to launch.
Figure 1.
Schematic diagram of single-stage electromagnetic weft insertion.
2.2. Multi-Stage Intermittent Electromagnetic Weft Insertion
Single-stage electromagnetic weft insertion can meet the weft insertion requirements of conventional width (4~5 m). To achieve the extra-large width (12 m) weft insertion speed requirement, multi-stage intermittently accelerated weft insertion is required. The principle is shown in Figure 2. A plurality of single-stage acceleration coils are arranged side by side along the axis, and the center of the coil is provided with a ring cavity. All the acceleration coils are coaxial to form a cylindrical movement channel. The weft clamp moves along the central axis in the movement channel and is accelerated by multiple stages. The speed is increased step by step to meet the demand for extra-large width weft insertion speed. Since the coil and the weft gripper are of equal length, the weft gripper receives an electromagnetic acceleration force from entering the coil. Once the weft gripper exits the coil port, it will receive a reverse electromagnetic resistance. Therefore, the acceleration coil needs to be turned on and off in time. In this way, the best possible overall transmission efficiency of the system is ensured.
Figure 2.
Principle diagram of multi-stage intermittent electromagnetic weft insertion.
2.3. Segmented Combined Continuous Acceleration Electromagnetic Weft Insertion
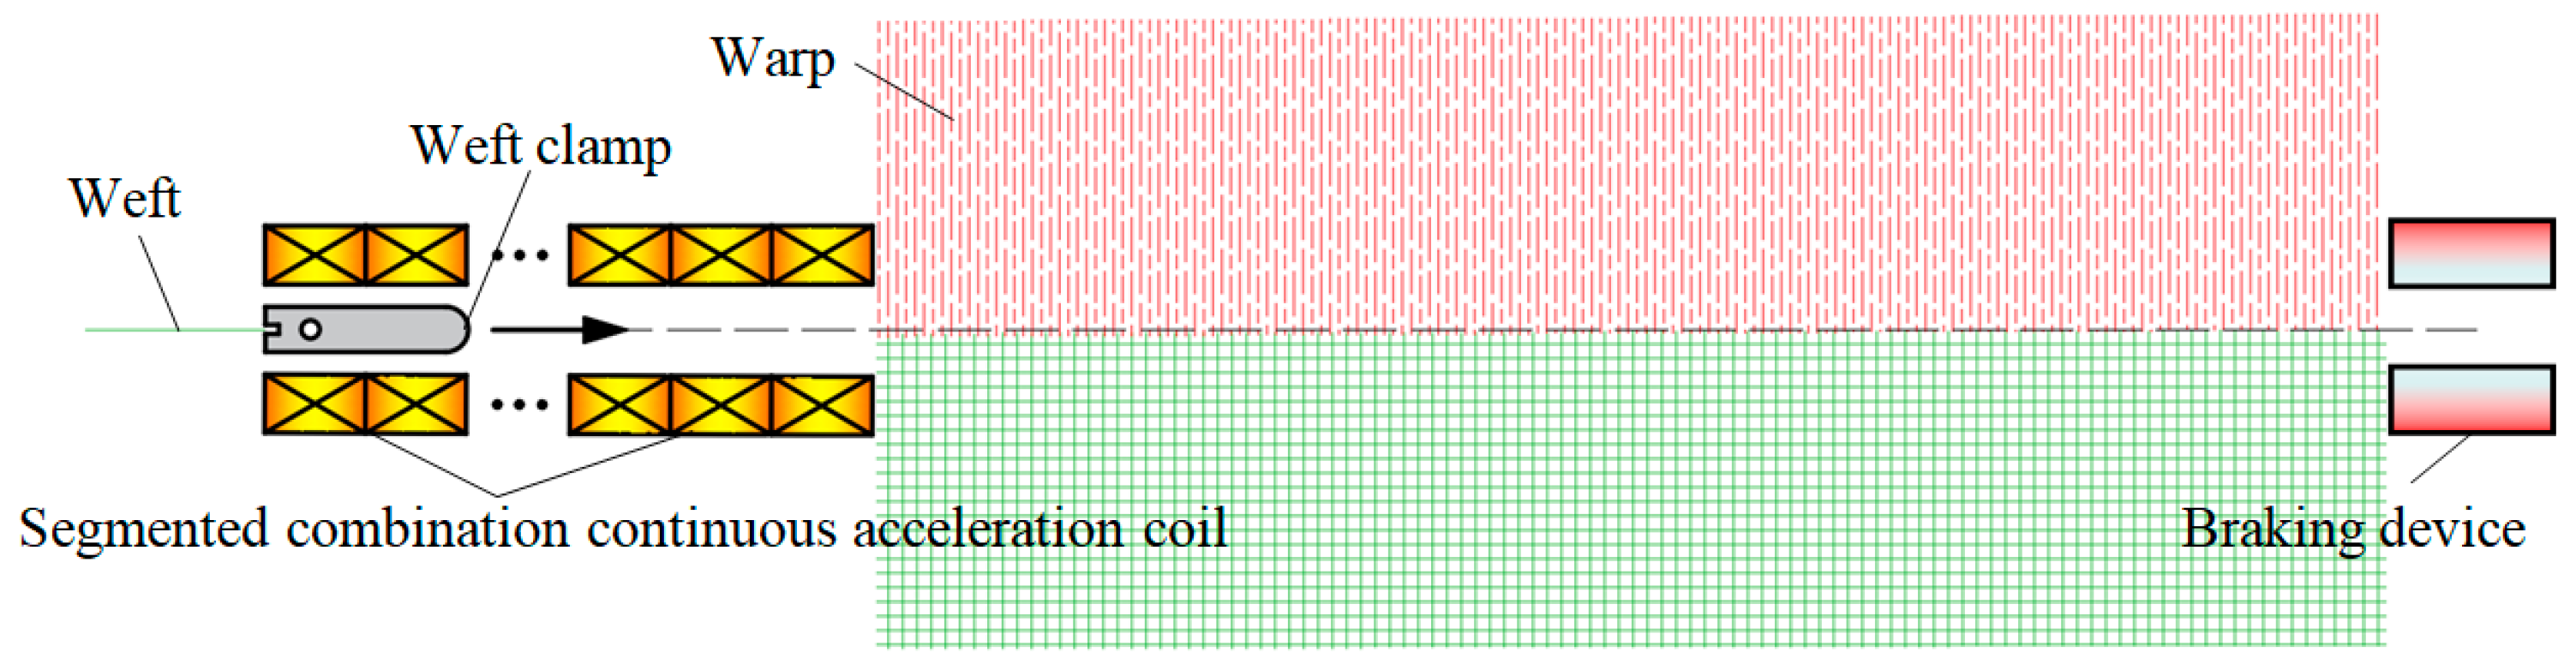
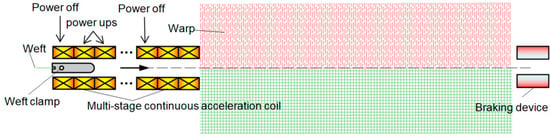
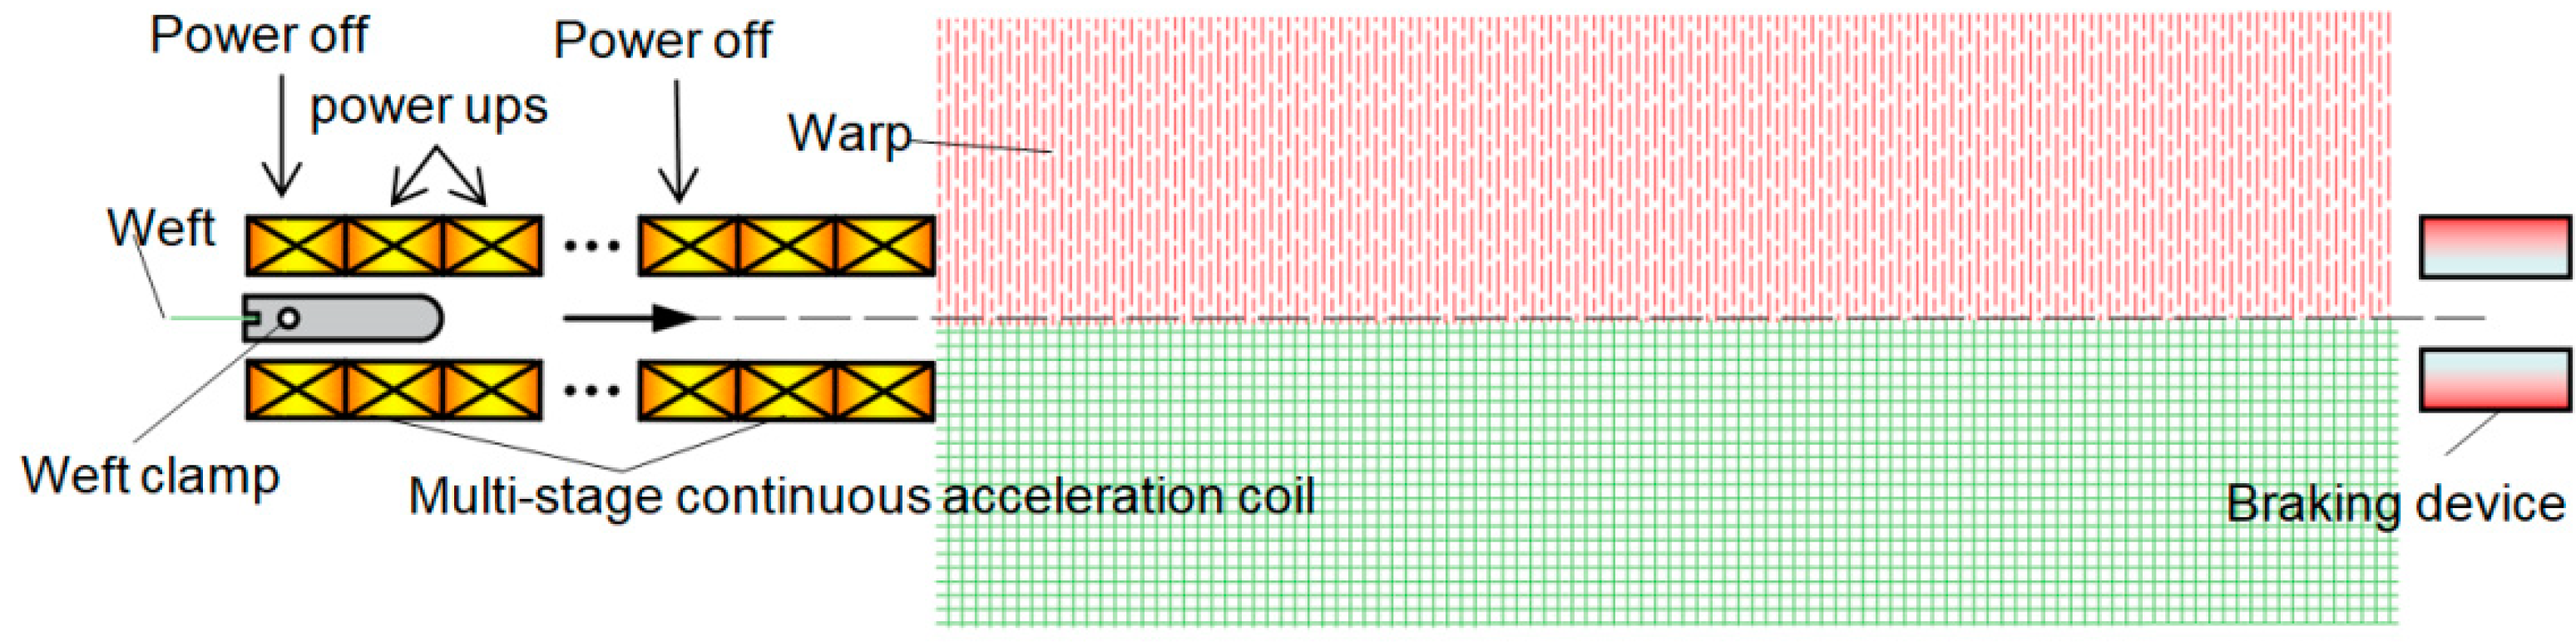
On the basis of the multi-stage intermittent electromagnetic weft insertion method, the coil structure is further optimized, resulting in the entire system having lower energy consumption, fewer consumables, and a further reduced overall volume of the acceleration coil. In contrast to the multi-stage discontinuous acceleration coil, the principle of the segmented combined accelerating coil is shown in Figure 3. The length of the segmented combined coil is 1/n of the multi-stage interrupted coil, which is 1/2 in Figure 3. Accelerating coils (greater than or equal to 3) are arranged in sequence along the axis, coaxially arranged side by side, forming a coaxial connection from end to end, rather than a discontinuous ring cavity. The acceleration principle is the same as that of the multi-stage discontinuous type. The segmented combined type needs to control the power of the weft gripper into the coil on and off, so that the weft gripper can be efficiently accelerated throughout the entire process. For example, in Figure 3, two adjacent coils are energized at the same time to form a superimposed electromagnetic field. The two segmented combined small coils are equivalent to a discontinuous acceleration coil. By analogy: m segmented combined coils are equivalent to m − 1 multilevel interrupted coils, and the length of each segmented combined coil and consumables are only 1/2 of a single multilevel interrupted coil. Compared with the multi-stage intermittent electromagnetic weft insertion device, the sectional combined type reduces the manufacturing cost and the operating cost, and has stronger adjustable ability, and higher efficiency and reliability.
Figure 3.
Schematic diagram of segmented combined continuous acceleration electromagnetic weft insertion.
3. Design of Piecewise Combined Continuous Accelerating Electromagnetic Weft Insertion Structure
3.1. Analysis of the Structure of the Weft Clamp
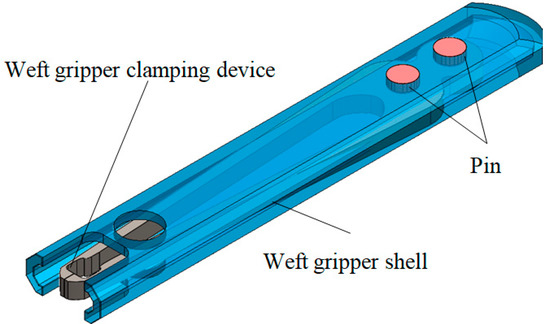
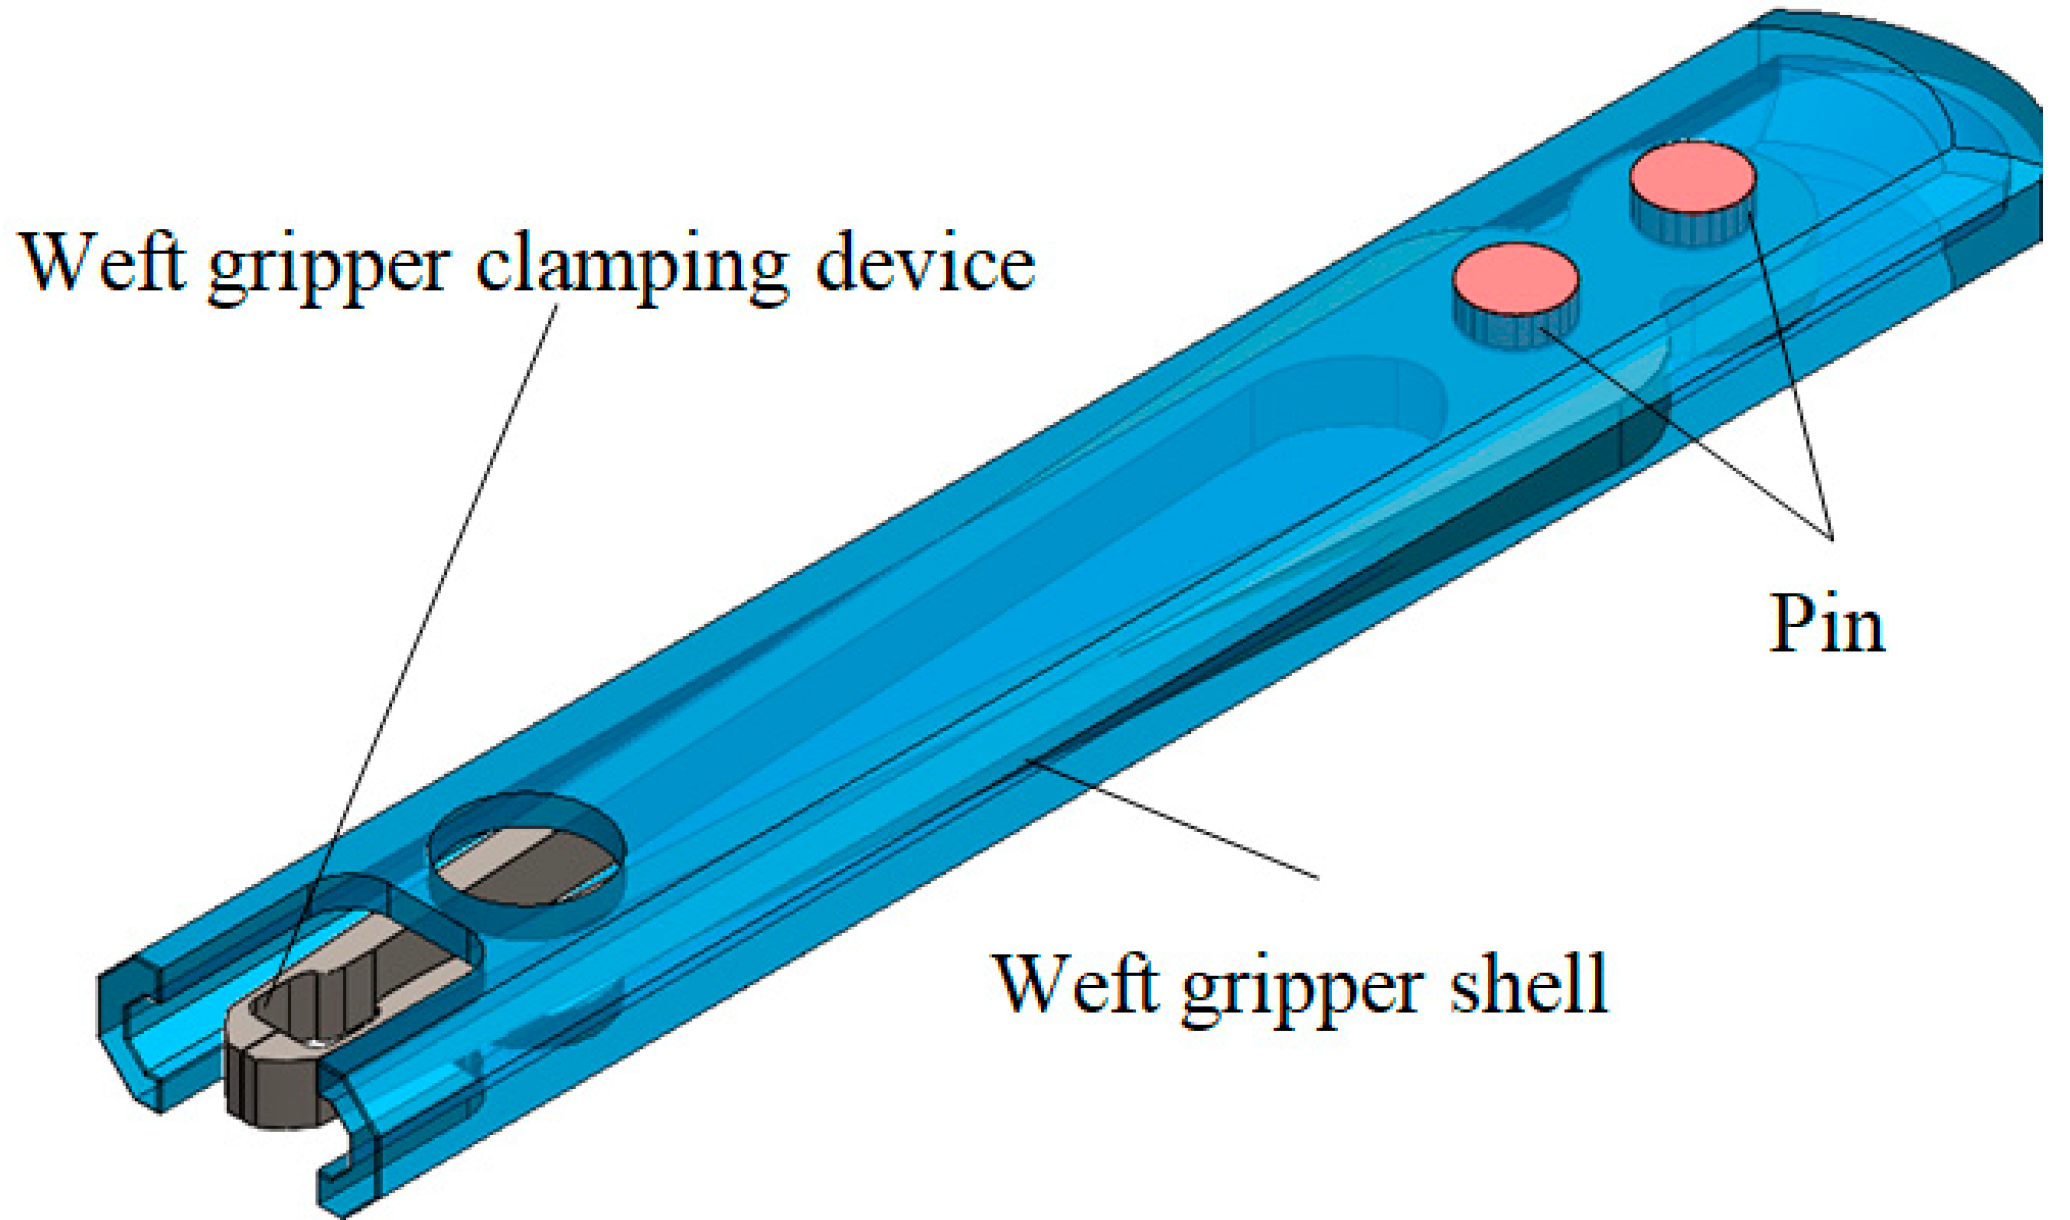
The main body of the weft gripper is composed of the weft gripper shell and the weft gripper clamping device inside, as shown in Figure 4. The outer shell of the gripper has a hollow structure, and the shape of the shuttle head and body is streamlined, which is conducive to the smooth flight of the gripper. The overall weight of the weft gripper is about 50 g, and the outer dimensions are: length 90 mm, width 14 mm, and height 6 mm; the thickness of the weft gripper clamping device is 3 mm. The adoption of a new electromagnetic weft insertion device eliminates the need to apply lubricating oil to the weft grippers running on the loom, and ensures the best cleanliness of the fabric. It is not only suitable for the weaving of most common fabrics, but also for weaving fine, extra-light-colored high-grade fabrics.
Figure 4.
The structure diagram of the weft clamp assembly.
The surface of the weft gripper needs to be heat treated, then finely ground into a prescribed streamline shape, and then polished to make the surface smooth and free of burrs. Different from the traditional projectile, the weft picking method is no longer adopted because of the electromagnetic drive launching weft insertion, which diverges significantly from the process requirements of the weft gripper. The shell of the weft clamp in this paper is made of ferromagnetic material, electrical pure iron which has high relative permeability, high conductivity, and low coercivity. Pure iron is easily oxidized in the air. In order to make the ferromagnetic weft clamps reusable, the coating method, electroplating method, and chemical methods to form dense oxide film-related processes are mature, e.g., in the film forming process The introduction of Zn ions can not only combine with more TA molecules to form a thicker conversion film, but can also accelerate the film formation process and convert it into ZnO, further inhibiting iron corrosion (corrosion protection efficiency can reach 92.39%) [15]. Studies have shown that the optimal strength of TIAIN coating is almost equal to the surface strength of pure iron, and that the coating variants do not undergo oxidation corrosion, which can perfectly protect the iron surface [16]. Electrochemical quantitative studies using gallium (III) and zinc (II) metal surfactants as iron corrosion retarders in salt and acid media have shown that they have mitigating effects [17].
The structure of the clamping surface is divided into flat clamping surface, notched clamping surface, toothed clamping surface, corrugated clamping surface, and anilox clamping surface, etc. As shown in Figure 4, the planar structure type is selected in this paper. A key part of clamping the yarn is the extra-large width automatic loom being opened and closed twice during each weft insertion process. In order to prevent fatigue and fracture during the opening and closing process, and to ensure that it has sufficient clamping force, the clamping device is made of 50CrV steel. The clamping device is heat-treated, and a force of 30 N is pre-applied to the clamping part during manufacture.
3.2. Sectional Combined Structure Design
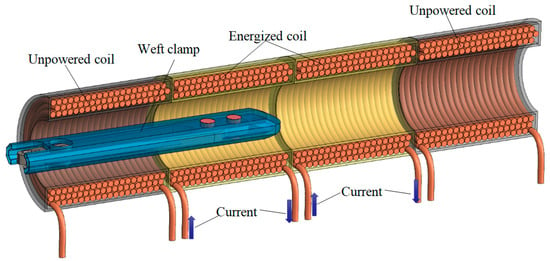
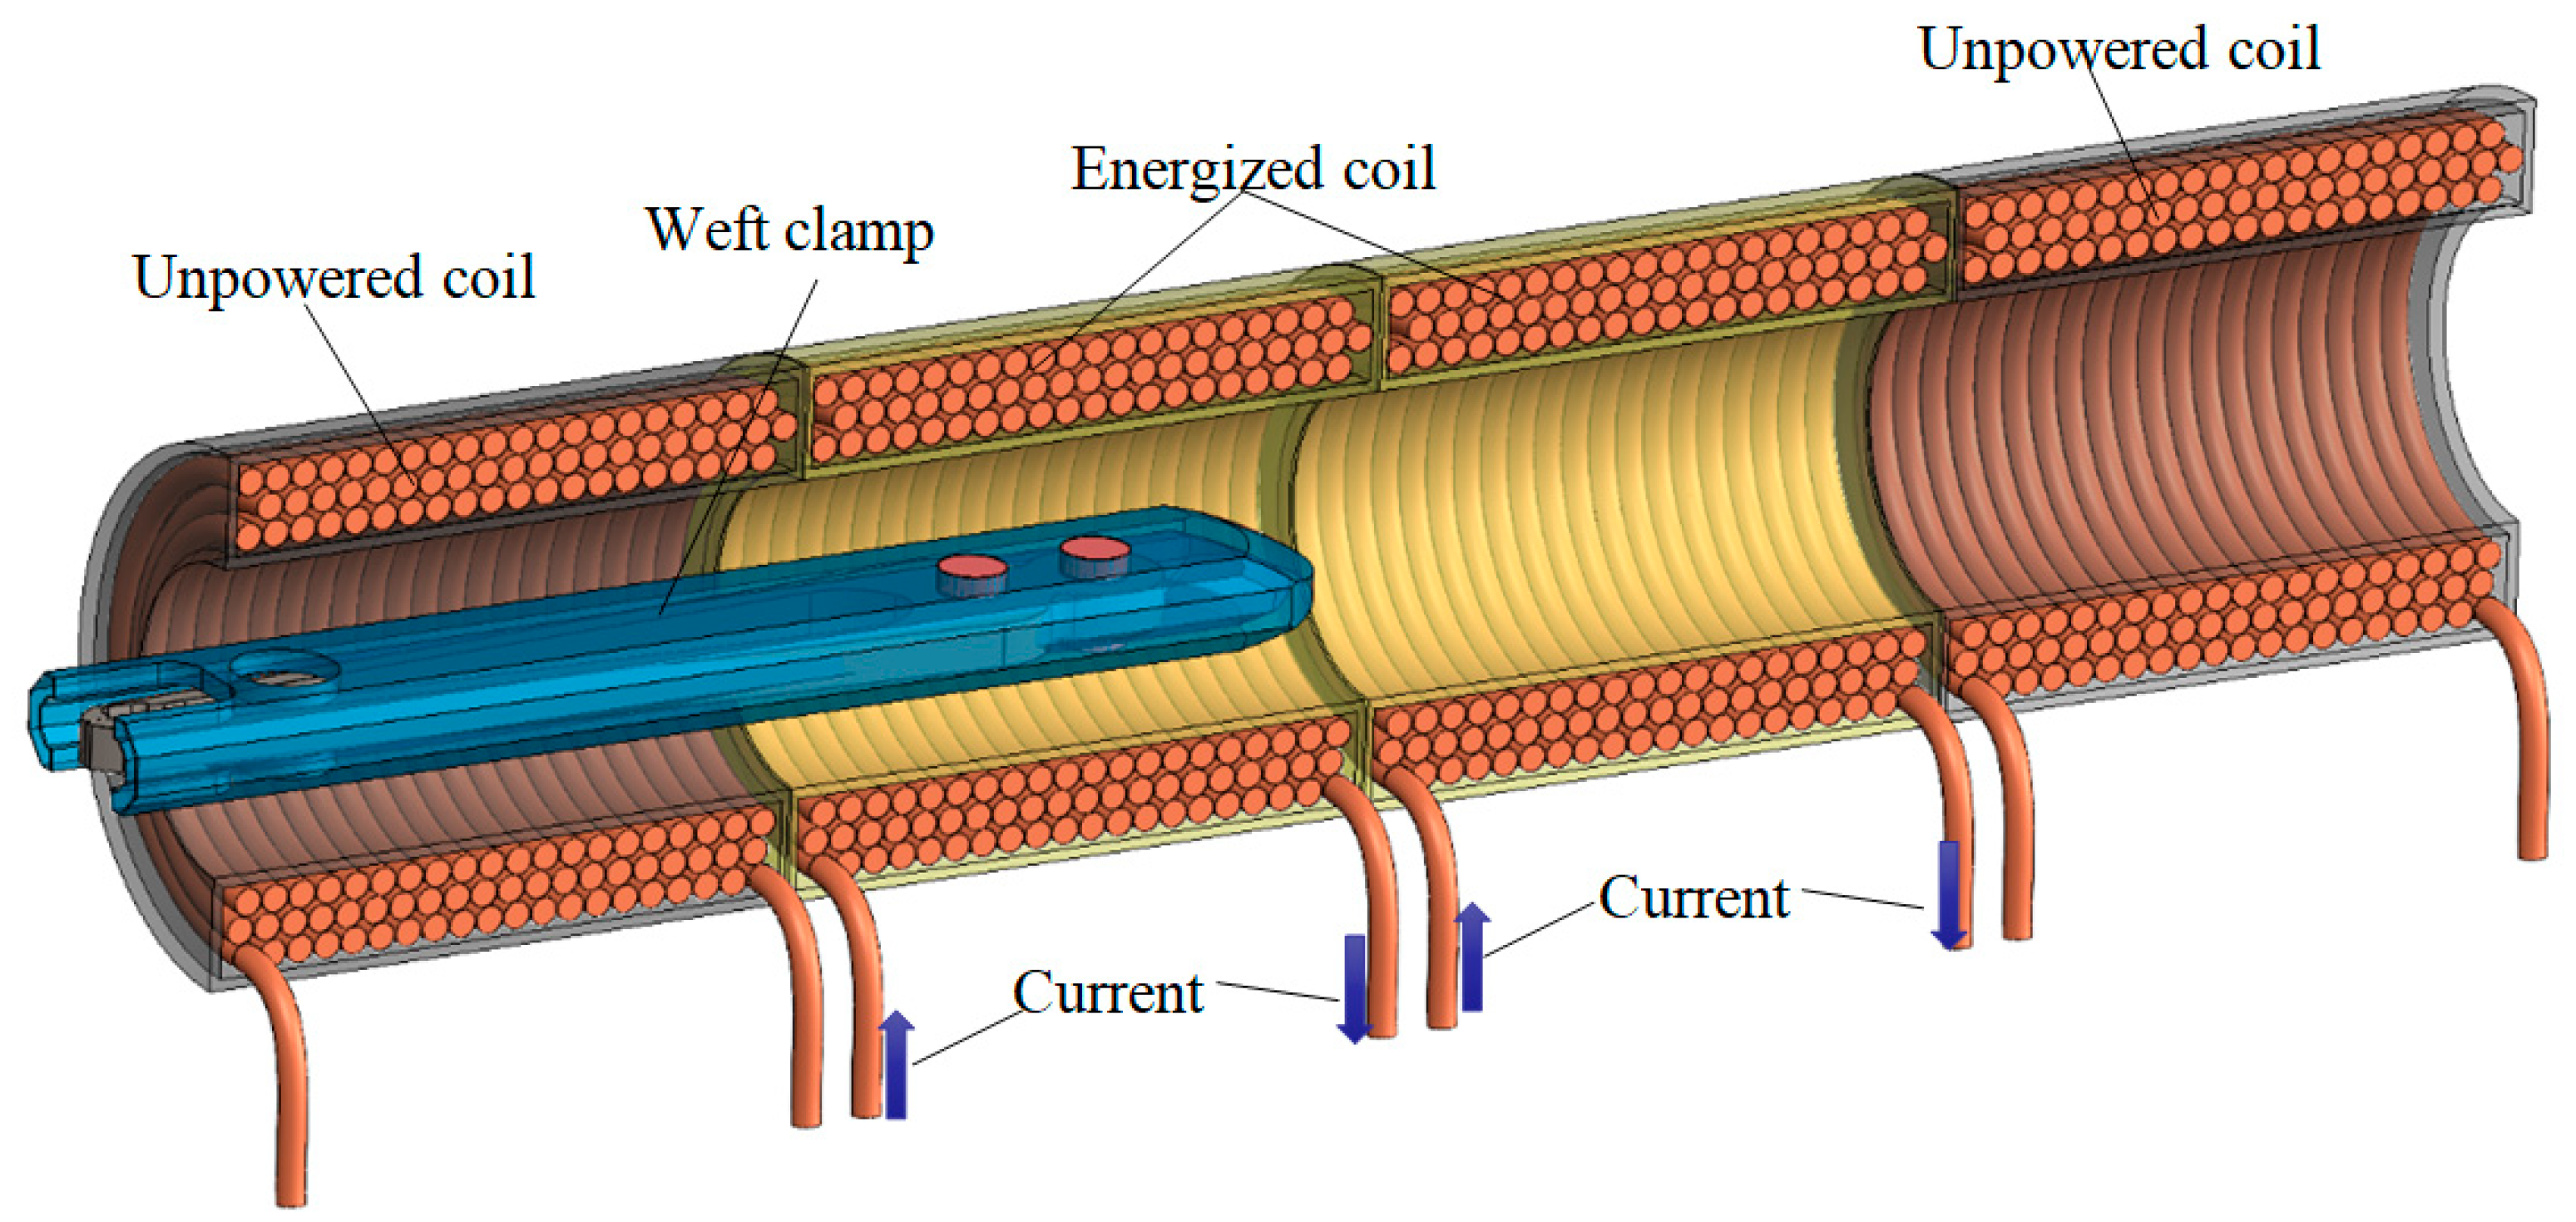
The 45 mm-long segmented combined acceleration coil consists of 10 coils arranged in order along the axial direction. Figure 5 shows the first four coils. A loop cavity is arranged in the middle of each coil, and each coil is connected continuously from end to end to form a cylindrical movement channel, so that the weft gripper can move along the axis direction in the movement channel. Each coil has a length of 45 mm, an outer diameter of 60 mm, an inner diameter of 18 mm, a yoke thickness of 1 mm, and an enameled wire diameter of 1 mm. Every two sections form a 90 mm superimposed magnetic field, the initial trigger position of the weft clamp is 45 mm, and the latter section of the two-section combined coil is used as an accelerant. When the weft gripper moves forward 45 mm, the next loop is energized, and the previous loop is powered off. The loop where the first half of the weft gripper is located and the previous loop that is about to enter are always energized to achieve the effect of high-speed acceleration throughout the process.
Figure 5.
Schematic diagram of a multi-stage segmented combined coil.
4. Analysis of Electromagnetic Weft Insertion Characteristics
4.1. Transmitting Coil Magnetic Field Analysis
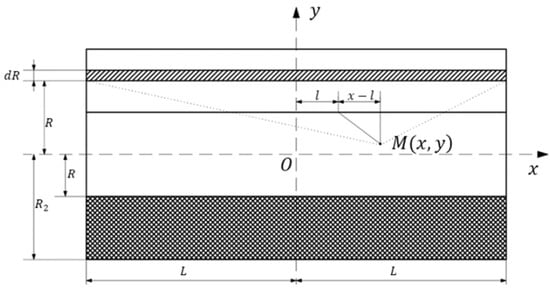
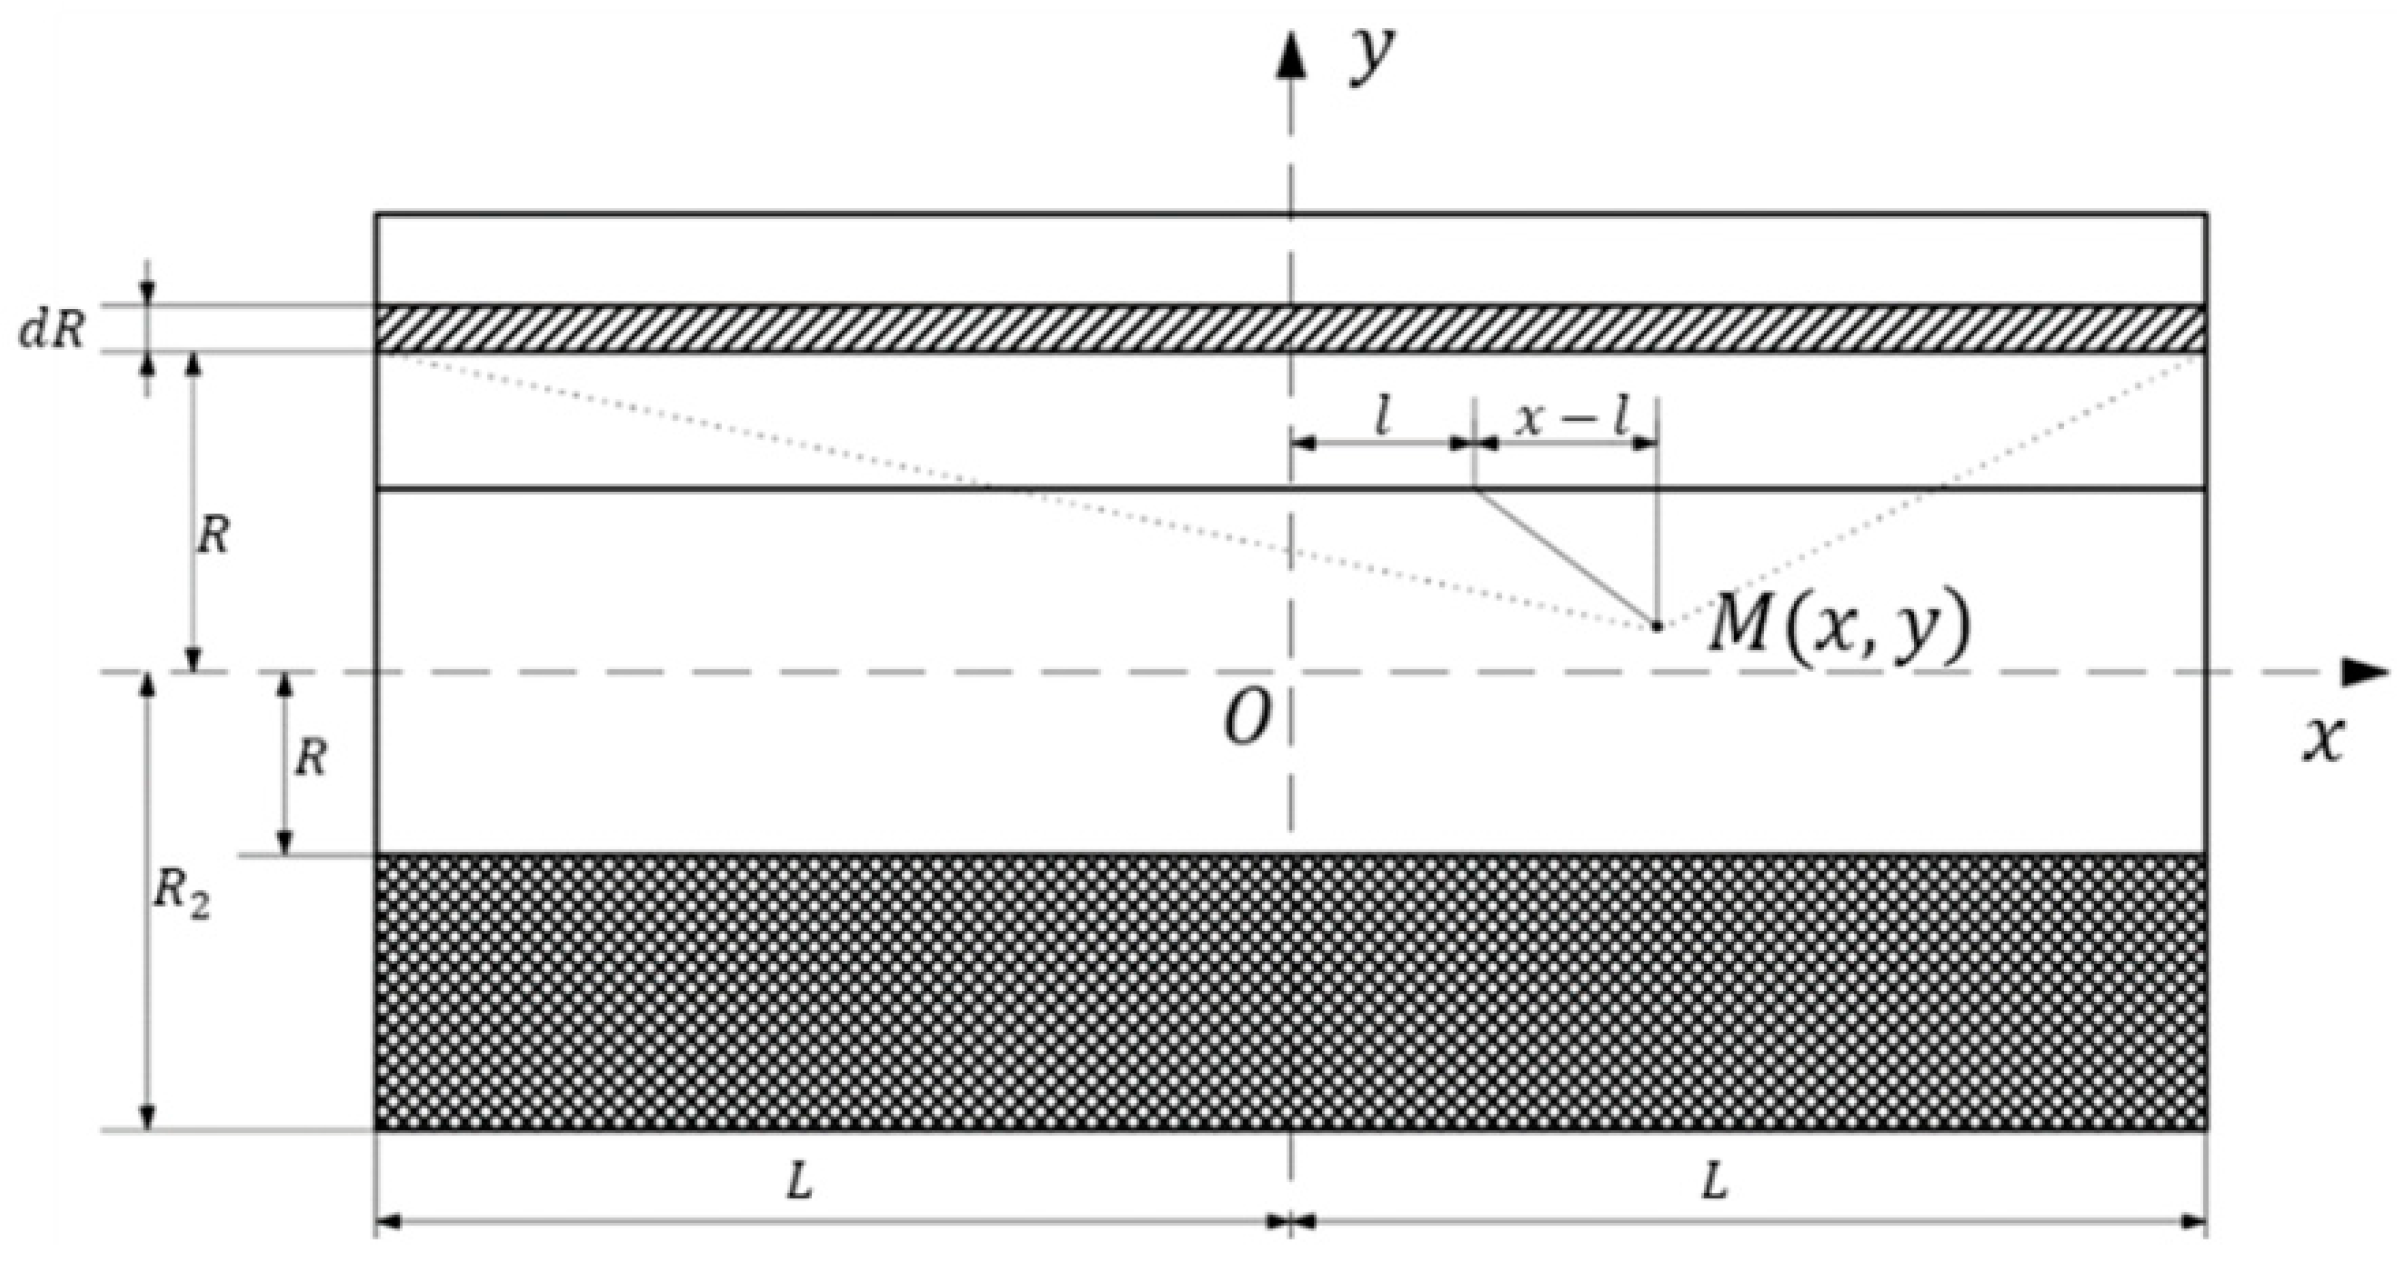
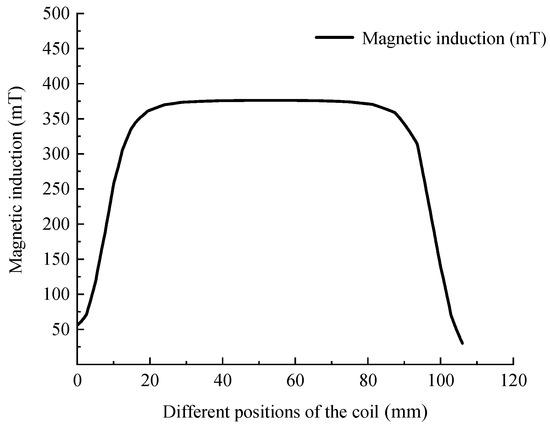
As shown in Figure 6, M(x,0) is any point on the axis of the coil, the inner radius of the coil is R1, the outer radius is R2, the total length of the coil is 2L, the current intensity is I, the number of turns is N, and j = NI/[2L (R2 − R1)] is the current density generated during continuous current distribution. The magnetic induction intensity at different positions inside the coil is shown in Figure 7. There are obvious rises and falls at both ends of the coil, and the gradient value is the largest. According to Biot-Savart law, the magnetic induction intensity on the central axis of the accelerating coil is [18]:
where: μ0 = 4π × 10−7 Wb/A,
Figure 6.
Schematic diagram of acceleration coil.
Figure 7.
Magnetic induction intensity inside the coil.
The magnetization vector M is used to describe the magnetization state of the magnetic medium. A macroscopic volume element ∆V is taken in the magnetic medium, and this volume element contains a large number of magnetic molecules. Using the ∑m molecule to represent the vector sum of the magnetic moments of all molecules in this volume element, the magnetization vector M can be expressed as:
After introducing the concept of magnetic susceptibility χm, the magnetization vector can also be expressed as:
When the magnetization M is known, the additional magnetic induction intensity B′ can be calculated from it. Then the additional magnetic induction intensity and the magnetic induction intensity Bx of the axis of the magnetizing field are superimposed together to obtain the magnetic induction intensity B of the ferromagnetic weft clamp in the coil. Among them, B′ can generally be ignored in calculation.
4.2. Electromagnetic Force Analysis
From the point of view of micro-elements, the weft gripper is regarded as a small cylindrical element segment with a radius of r and a height of ∆h. Because the net magnetic flux of the magnetic field emitted by the object is zero, each small element segment has radial and axial flux; the radial flux is recorded as 2πr∆hBj, and the axial flux is recorded as πr2[−B(x) + B(x + ∆h)]. Take the first-level approximation to the height of the micro-element section ∆h as:
If the total magnetic flux is zero, we can get:
Simplified:
Use the gradient of the magnetic field B to express the force acting on the dipole:
The circuit with the product of the same current and area produces the same magnetic field at a distance. The product Ia/c is called the magnetic dipole moment of the current circuit, and it is represented by m. The magnetic dipole moment is a vector, and the direction is the normal direction of the circuit. In other words, it is the direction of vector a, which is the area of the direction surrounded by the loop.
where I = Mcdx. The unit of I: electrostatic unit/second; the unit of a: square centimeter (cm2); the unit of c: centimeter/second (cm/s); and the unit of m: erg (10−7 J)/Gauss (10−4 T).
If a piece of material with a thickness of dx is cut perpendicular to the magnetization direction and divided into small micro-elements, the cross-sectional area of each small micro-element is ds. Since M is the dipole moment per unit volume, each small micro-element contains the total dipole moment Mdsdx. The magnetic dipole moment can be further simplified as:
The factor πr2I/c is the value m of the magnetic dipole moment of the current loop, so Equation (8) is further simplified as:
Combining Equations (10) and (12) together, we get:
The unit of F in the above two formulas: dyne (10−5 N); the unit of magnetic field gradient: Gauss/cm (G/cm). In
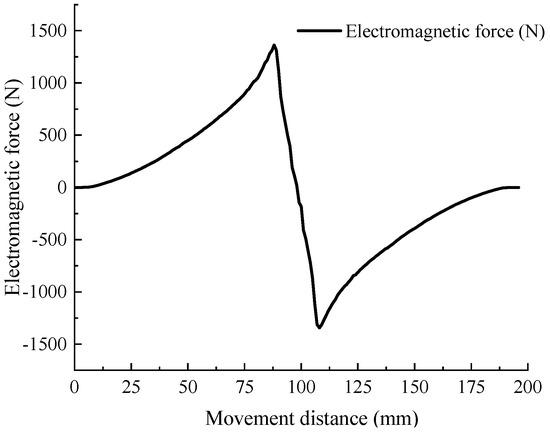
The electromagnetic force curve on the center axis of the coil is shown in Figure 8. After the gripper enters the accelerating coil, the electromagnetic force gradually increases. When the center of the gripper and the center of the coil are about to coincide, that is, when the top of the weft gripper is about to fly out of the accelerating coil, the electromagnetic force decreases sharply to zero and increases in the opposite direction. As the weft gripper flies forward, the end of the weft gripper flies away from the coil, and the electromagnetic force on the weft gripper continues to decrease until it reaches zero.
Figure 8.
Electromagnetic force at different moving positions of the weft gripper.
4.3. Motion Analysis
When the ferromagnetic weft clipper is moved by suction in the coil, if air resistance, and coil and circuit heat loss are not taken into account, according to the principle of energy conservation, the flying speed of the multi-stage coil (n-stage) in an ideal state is:
In the formula: m is the mass of the gripper, unit: kilogram (kg). n is the number of coil series.
During the weft insertion process, the weft flight trajectory can be kept approximately horizontal and straight for a long distance, but there is actually a drop of about 4.5 cm. The design parameters of the extra-large width are 12 m, the maximum speed is 200 r/min, the mass of the weft gripper is 50 g, and the weft gripper flies through the shed and takes up 120° of the spindle rotation angle. The final launch speed of electromagnetic weft insertion is required to reach 125 m/s upwards. From Formula (15), it can be seen that the ratio of the speed of the nth stage to the speed of the (n − 1) stage is:
Since the loss of air resistance and coil heating is not considered, and in order to avoid a significant waste of energy, the outlet speed range is set to 125–135 m/s. The minimum exit velocity is 125 m/s, which can be calculated by recursing Formula (16) forward. A total of nine levels of acceleration are required, and the first level needs to be accelerated to 41.7 m/s.
4.4. Simulation Analysis
In order to study the electromagnetic driving force generated by the extra-large width electromagnetic weft insertion drive coil and the weft insertion rate of the weft gripper during the weft insertion process, the effects of air resistance and temperature rise are ignored, and Maxwell software is used to simulate and analyze the segmented combined continuous acceleration device. The simulation parameter settings are shown in Table 1:
Table 1.
Simulation calculation parameters.
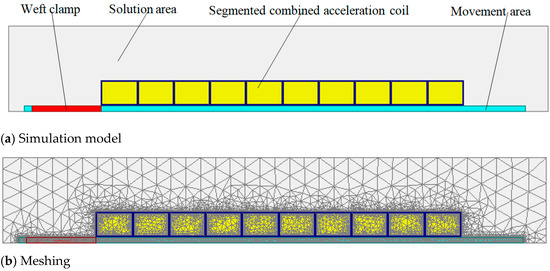
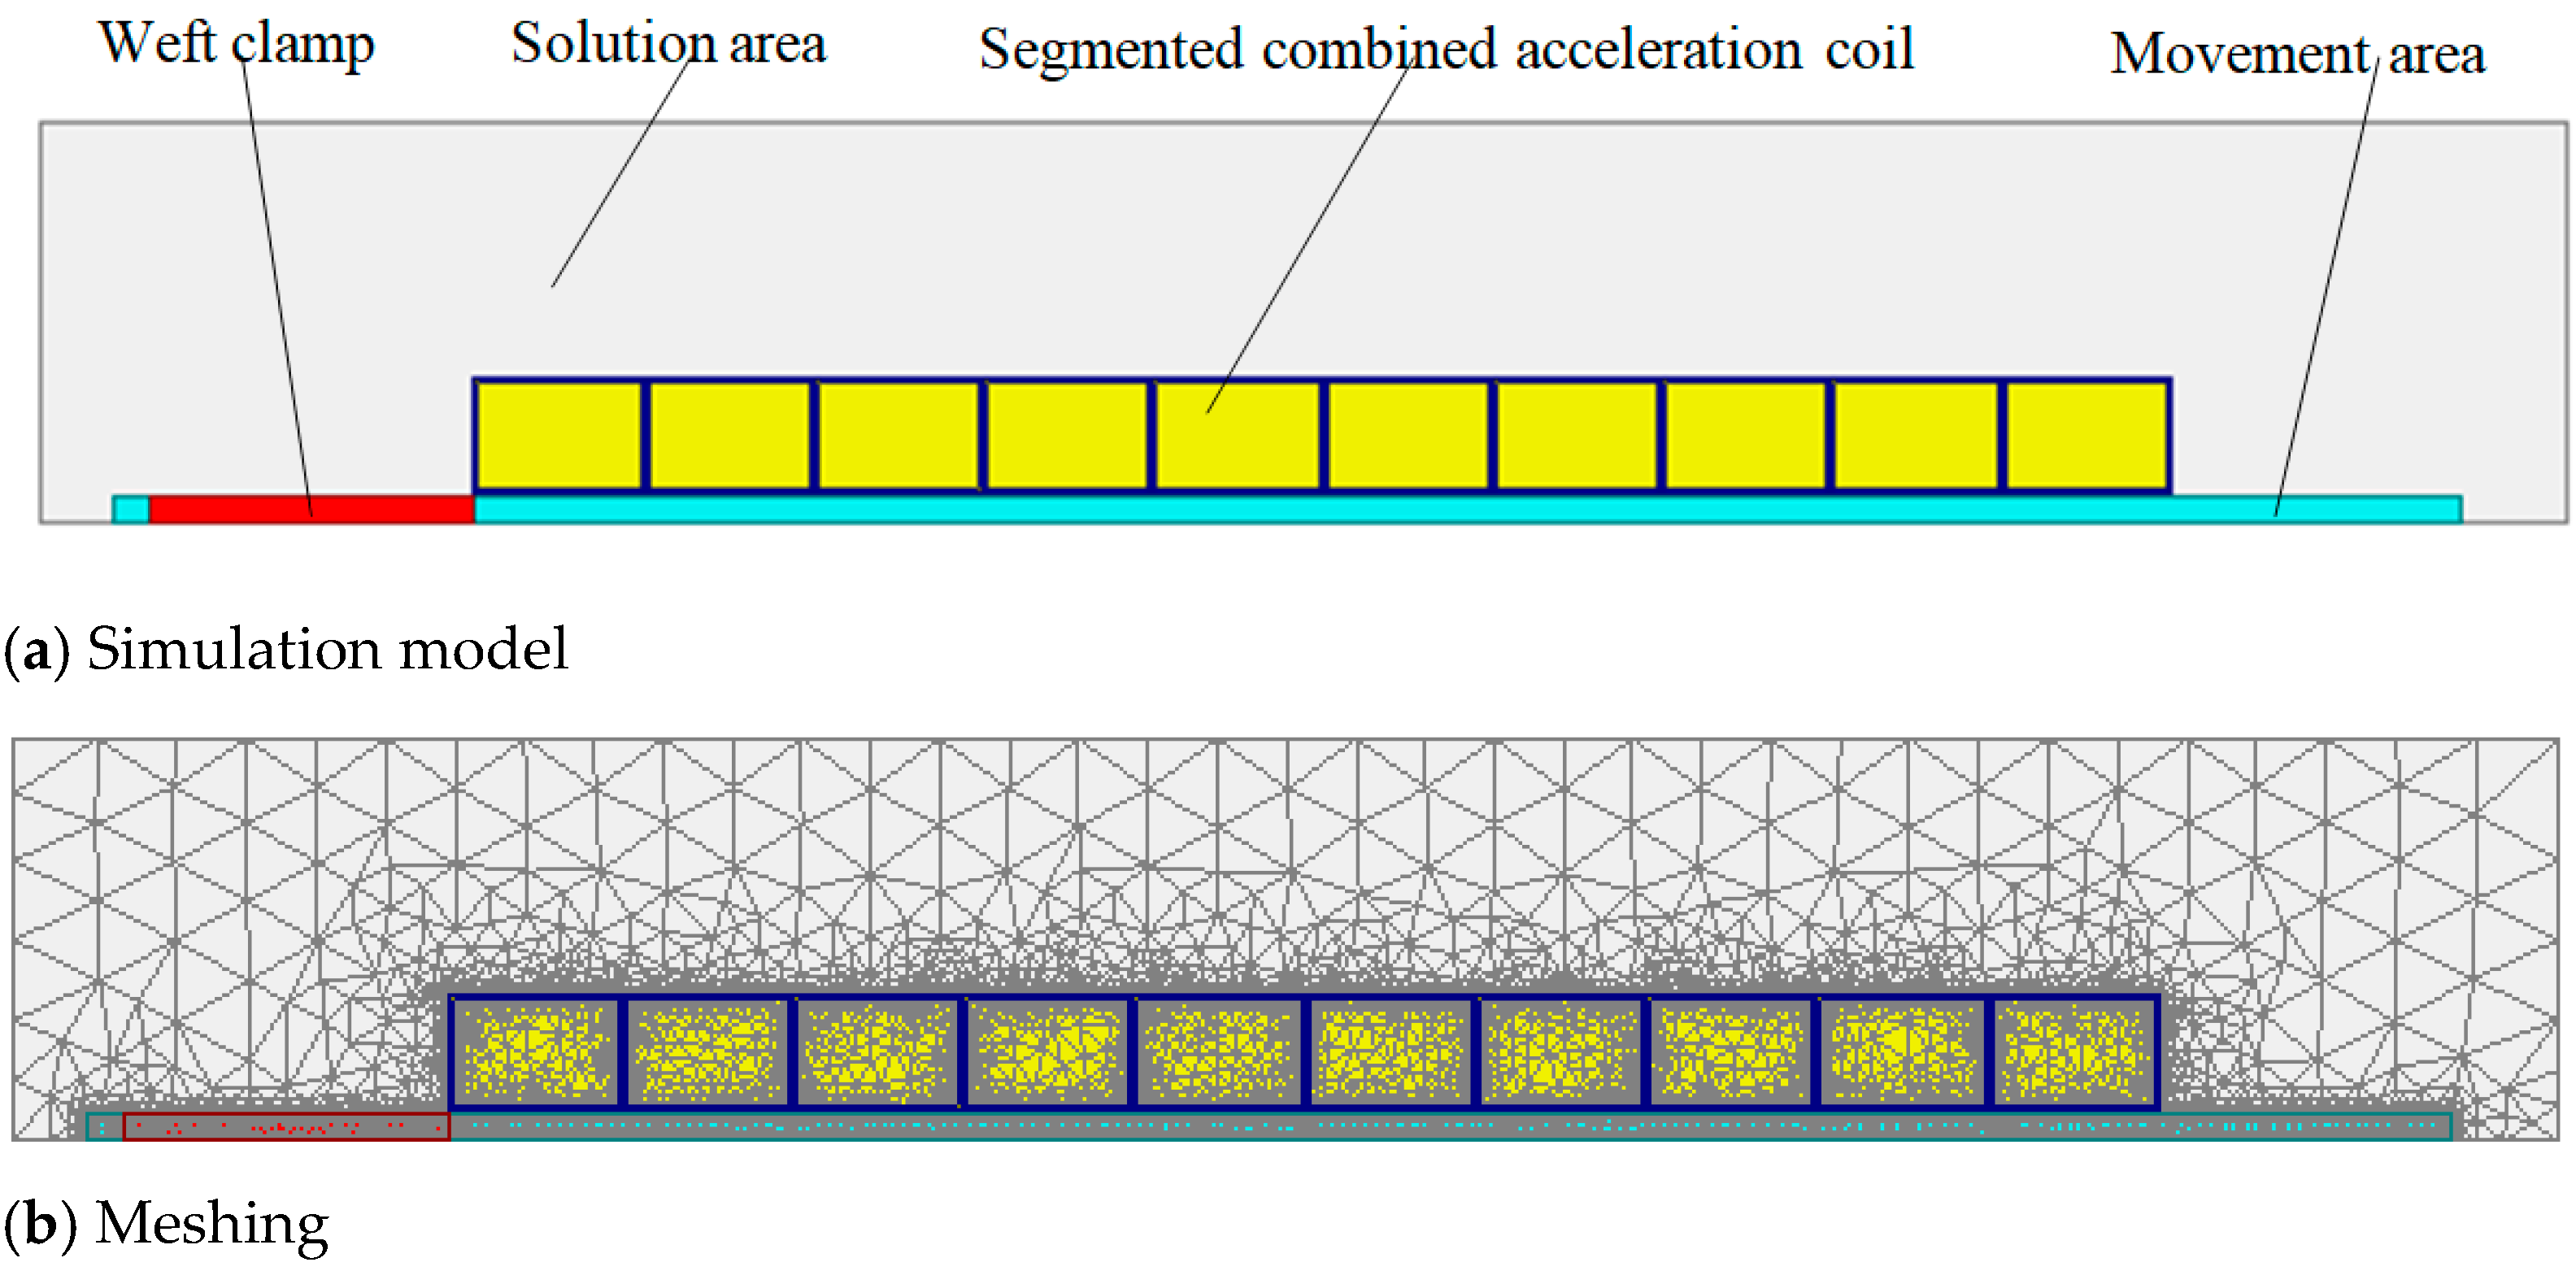
Figure 9a,b show the simulation model and grid division of the segmented combined 45 mm coil, respectively. It can be seen from the figure that the grid division of the weft clamp, the transmitting coil, and the moving area is relatively dense to ensure simulation calculation accuracy.
Figure 9.
Electromagnetic field simulation of segmented combined 45 mm coil.
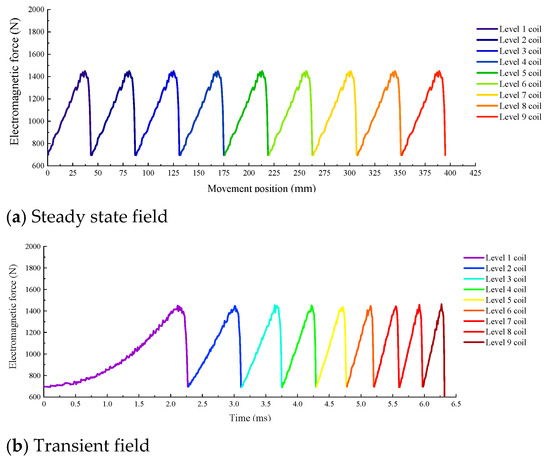
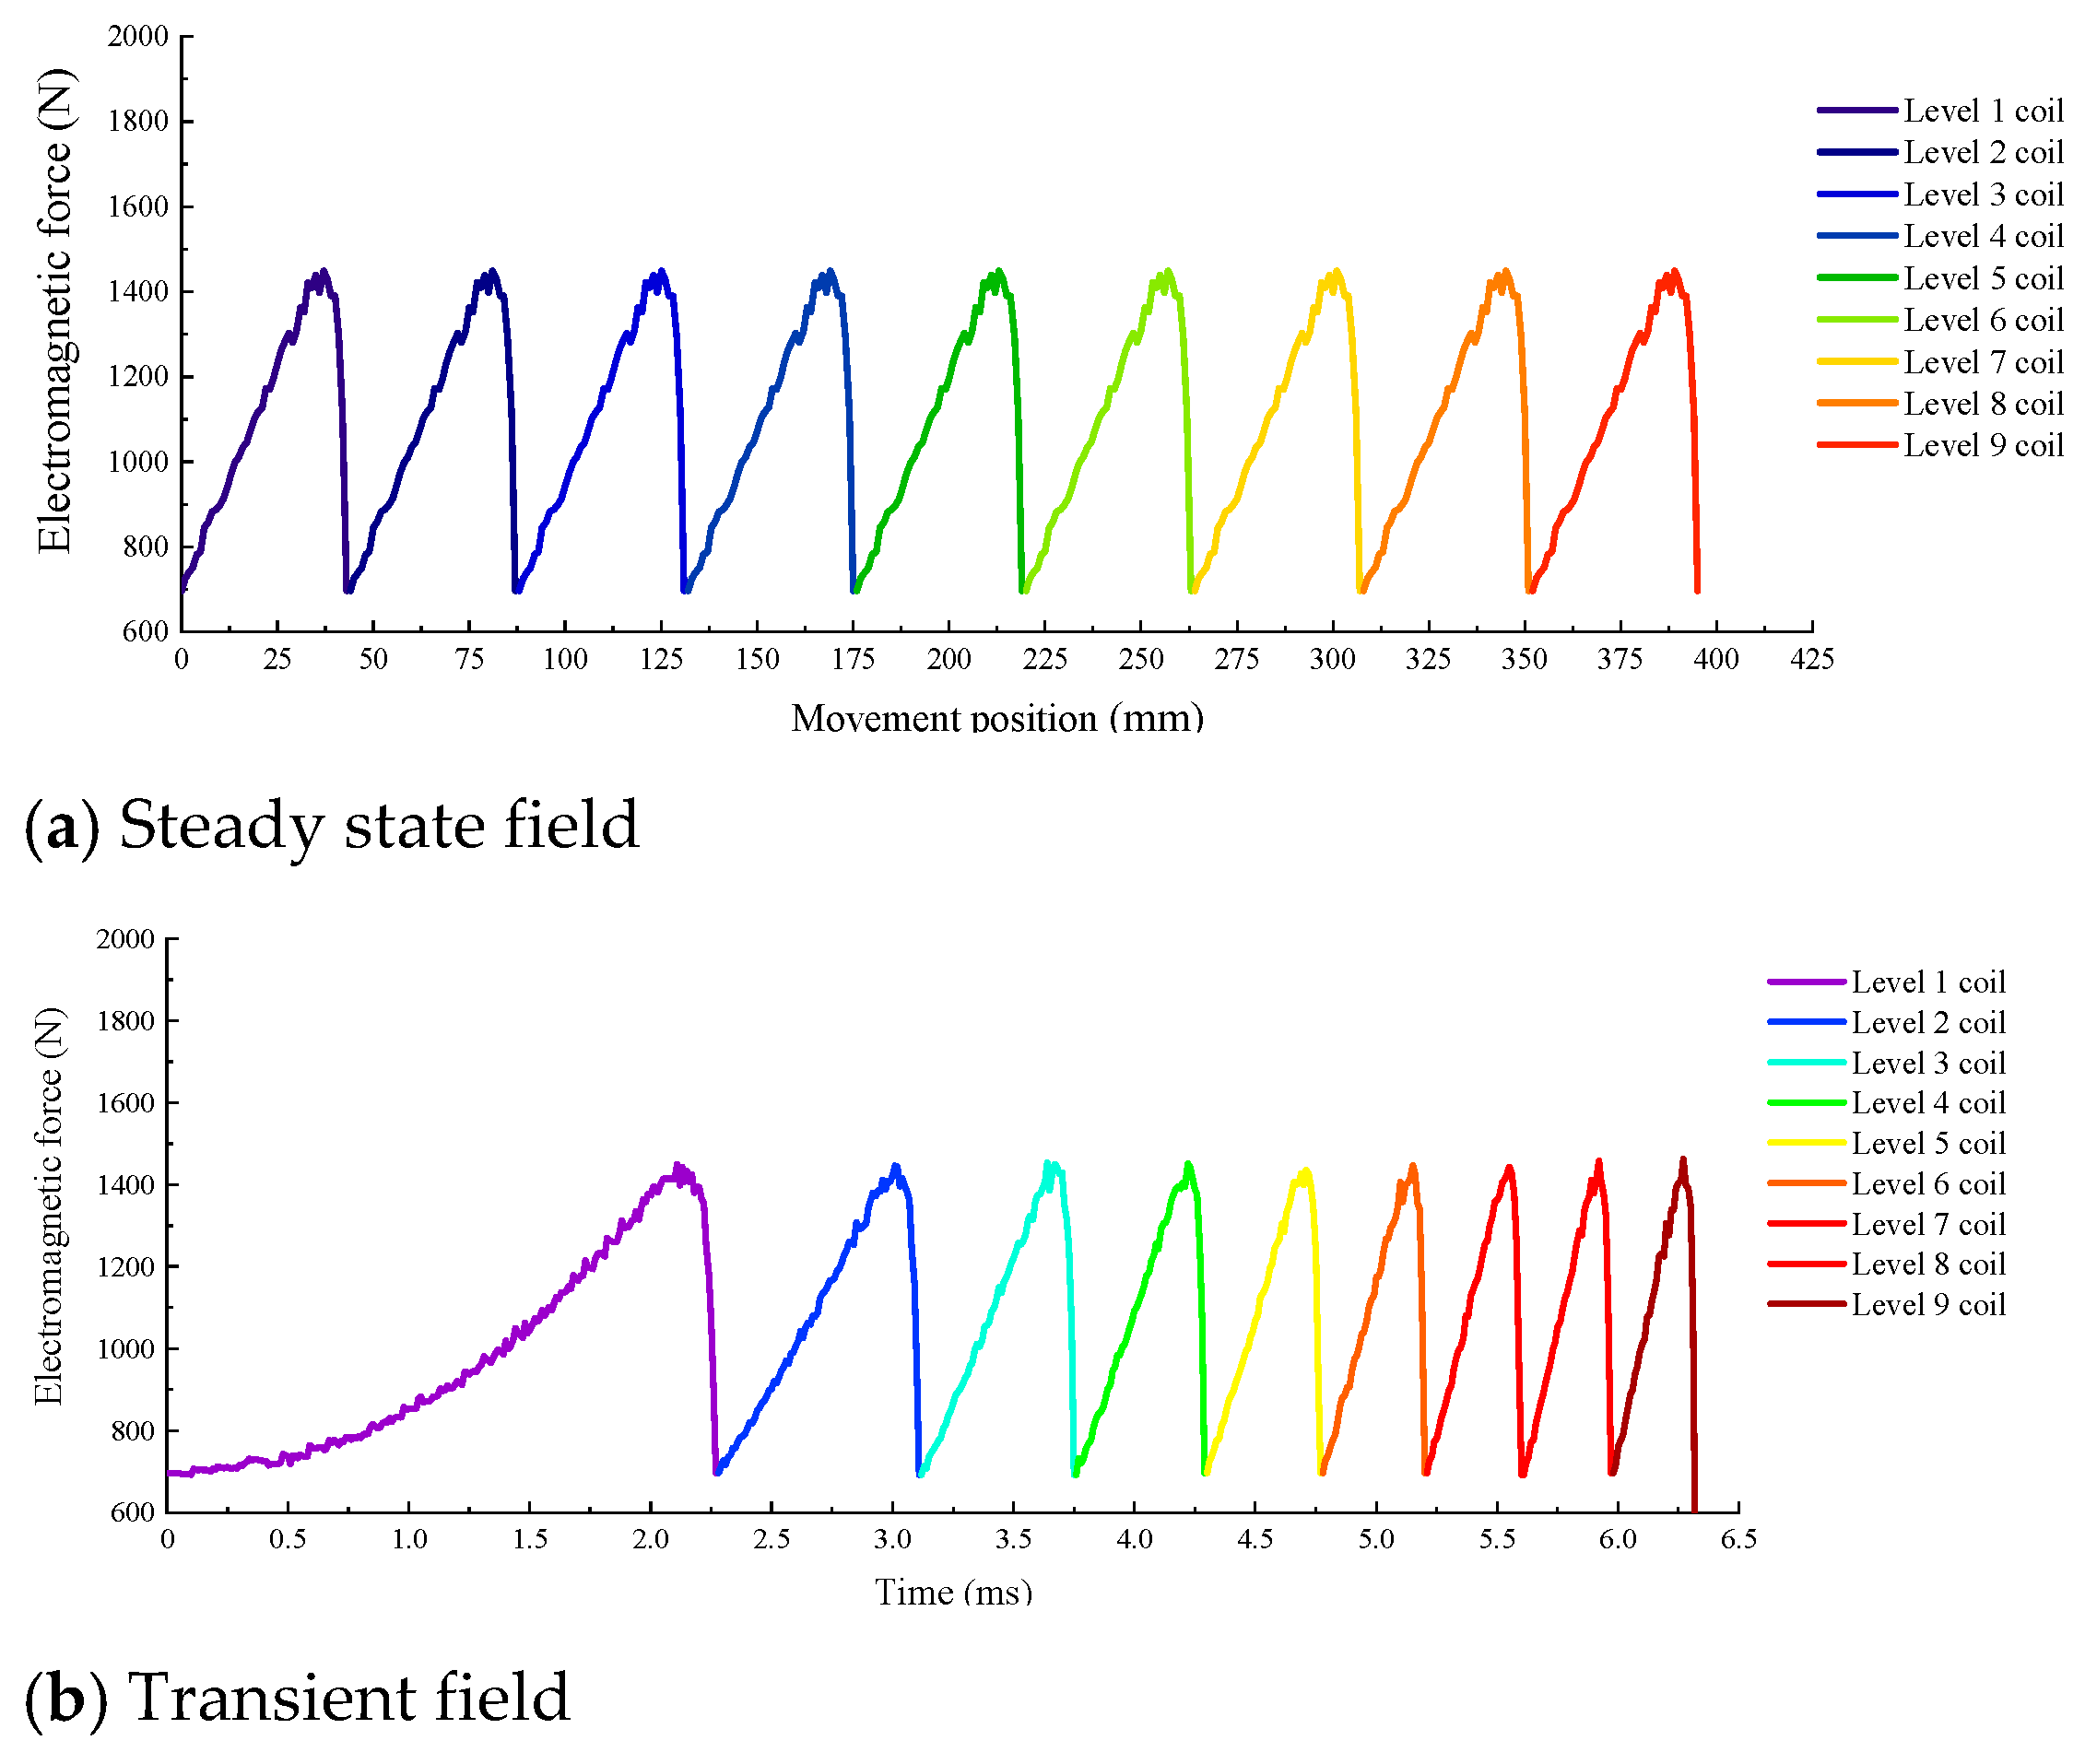
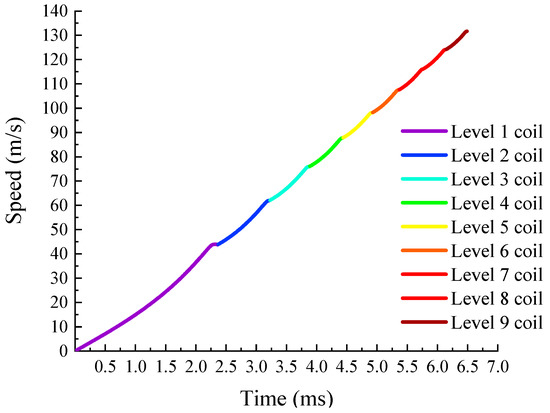
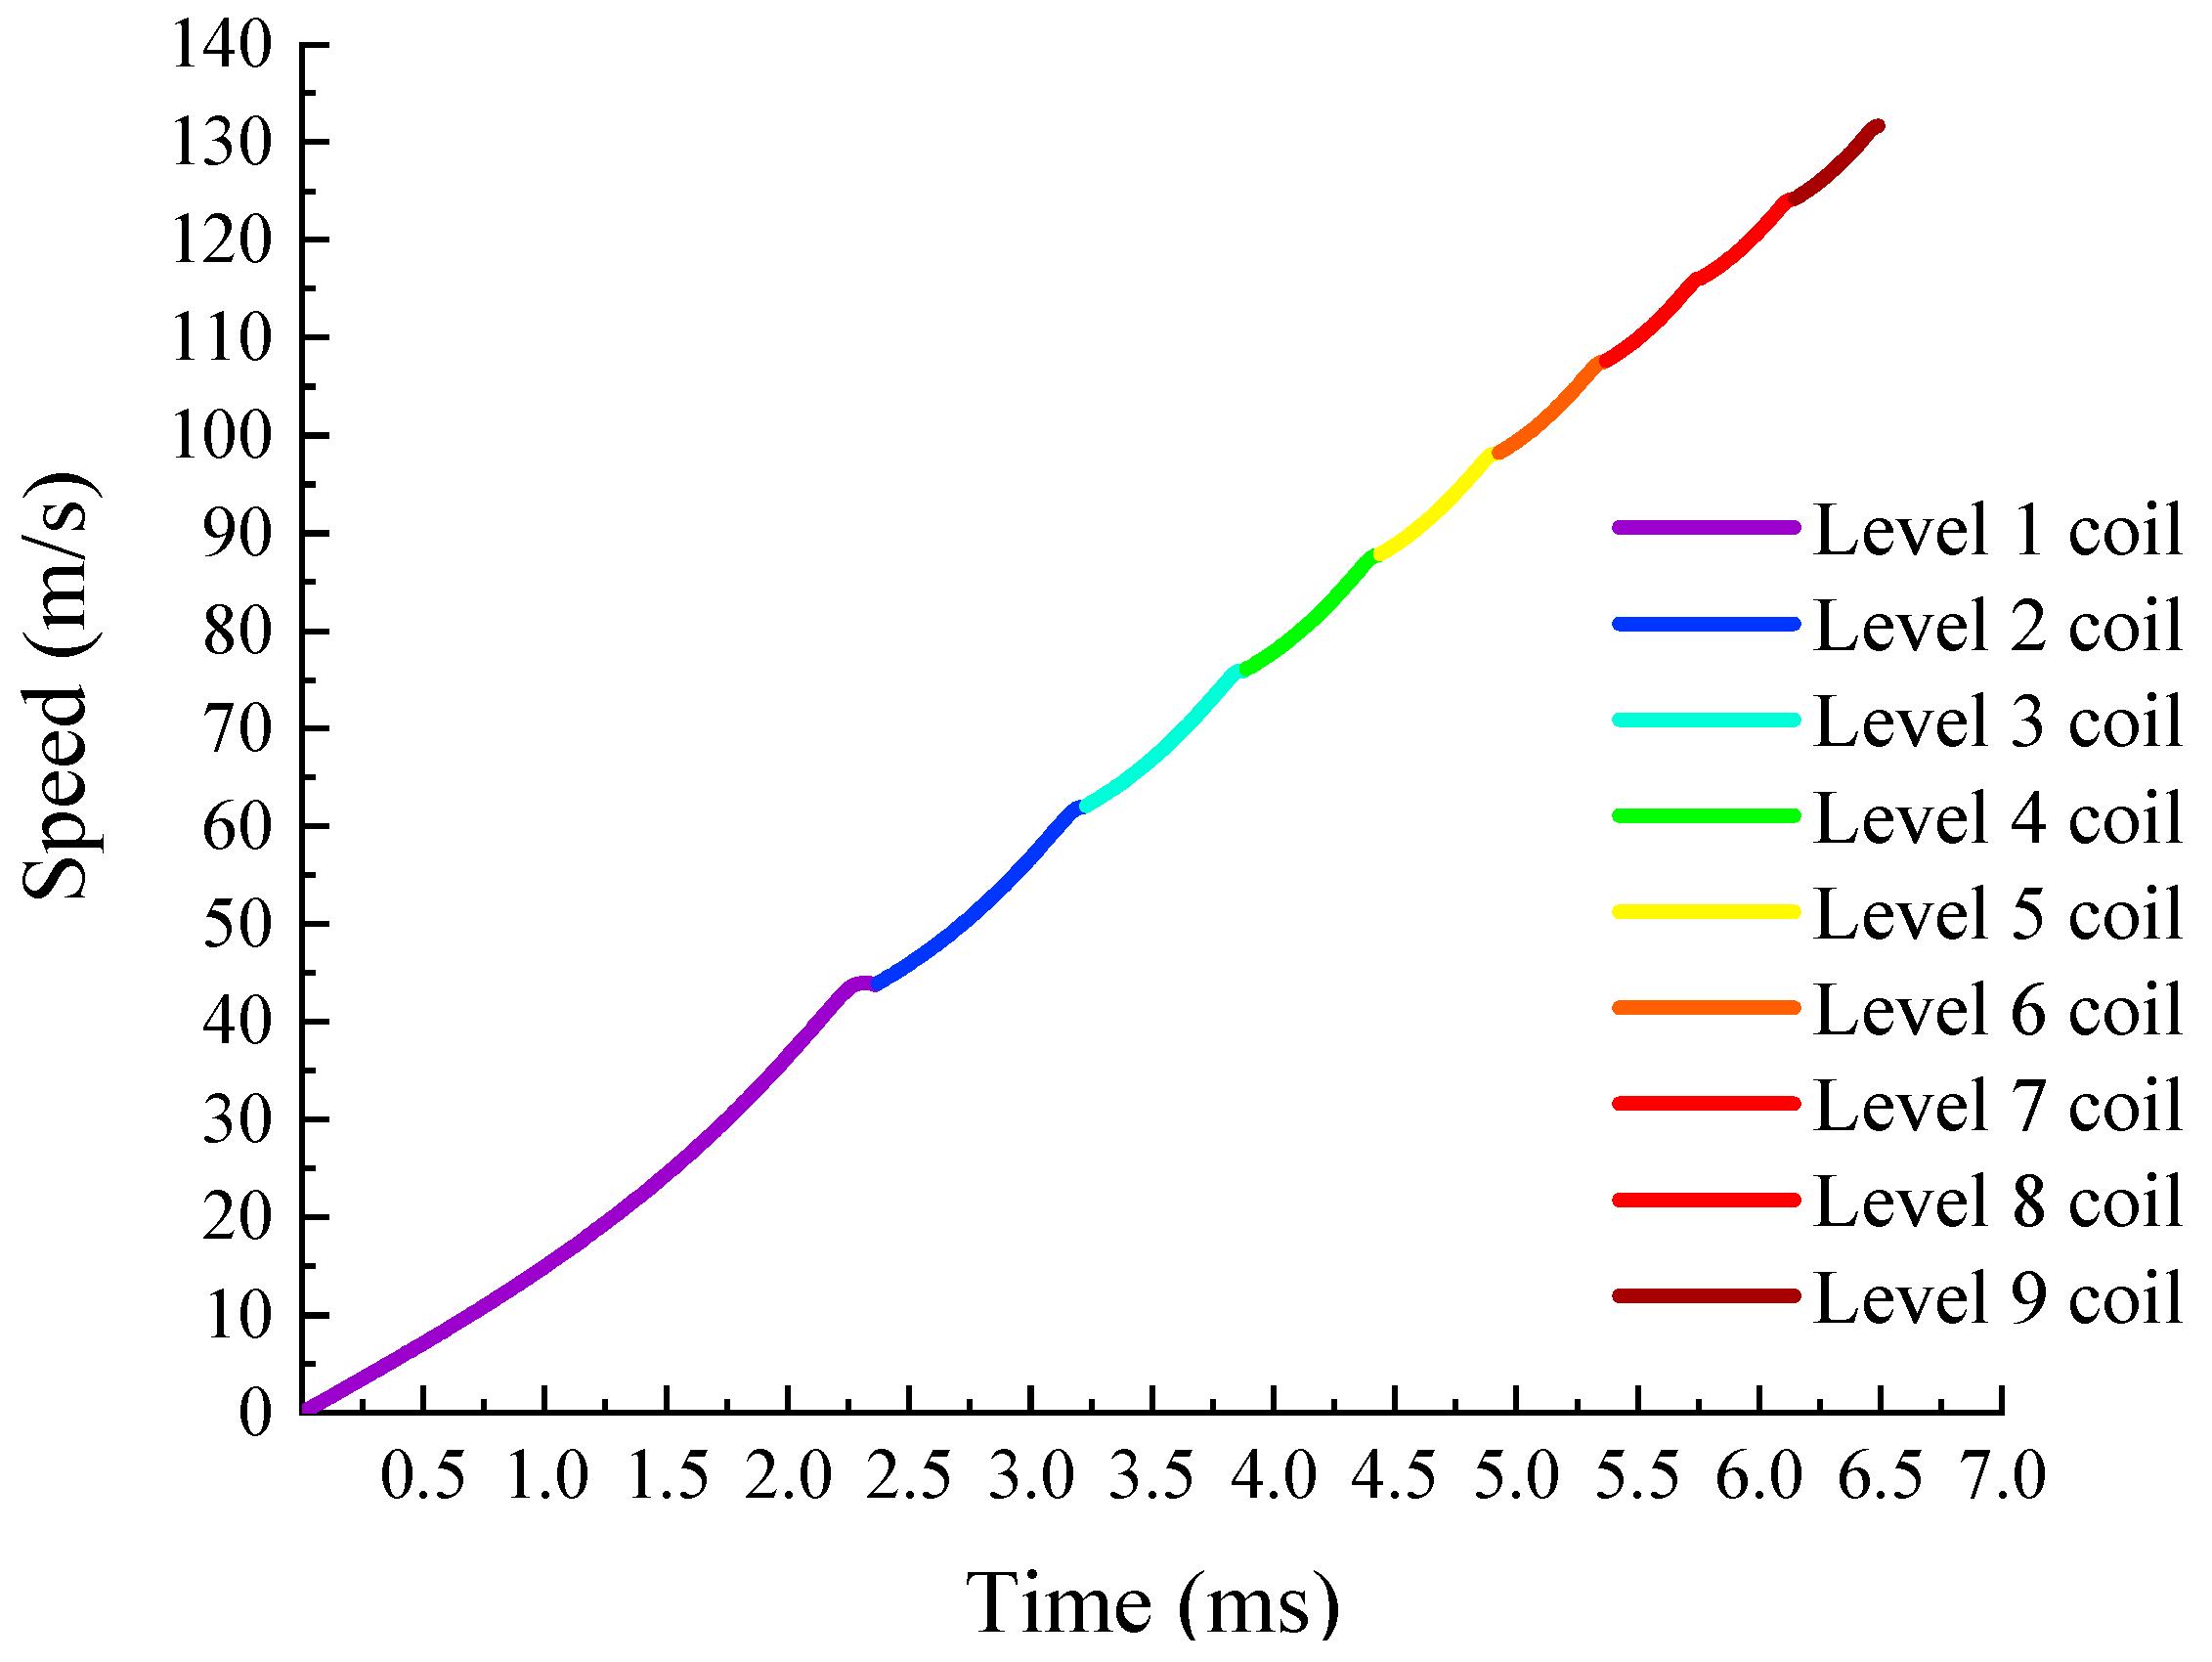
Figure 10 shows the change curve of the electromagnetic force in the steady state field (a) and transient field (b) of the weft clamp in the 45 mm segmented combined acceleration coil. In the steady state field, from level 1 to level 9, the electromagnetic force exerted by the weft gripper presents a pulsating trend with the coil length of 45 mm as the period. The electromagnetic force is maintained between 700 and 1400 N, and the average force is about 1000 N during the entire continuous segmented acceleration. Compared with the steady state field, under the transient setting, the overall trend of the electromagnetic force variation curve with time is consistent with the former, and the variation range is still 700~1400 N, but it does not show a periodic change law like the steady state field (a). The acceleration time of the combined coils from level 1 to level 9 decreases step by step. This is because under the acceleration of the segmented combined continuous accelerating coils, the weft gripper will fly faster and faster, and the length of the segmented combined coils of each stage will be the same, and the time spent in the flight process will be less and less. The flying speed of each level of weft gripper is shown in Figure 11. The speed as a whole presents a gradual increase trend, and the slope of the speed curve changes less, that is, the acceleration and electromagnetic force received are stable. The simulation speed of each level is shown in Table 2, and the increment ratio is consistent with the theoretical speed analysis.
Figure 10.
The electromagnetic force of the 45 mm continuous acceleration coil.
Figure 11.
The speed diagram of the weft gripper.
Table 2.
Comparison table of theoretical speed and simulation speed.
Table 2 shows the comparison between the minimum speed requirement of each level of 9-level coil acceleration theory and the speed obtained by the simulation of the segmented combined 45 mm coil. The results show that the segmented combined continuous acceleration coil meets the design requirements of electromagnetic weft insertion.
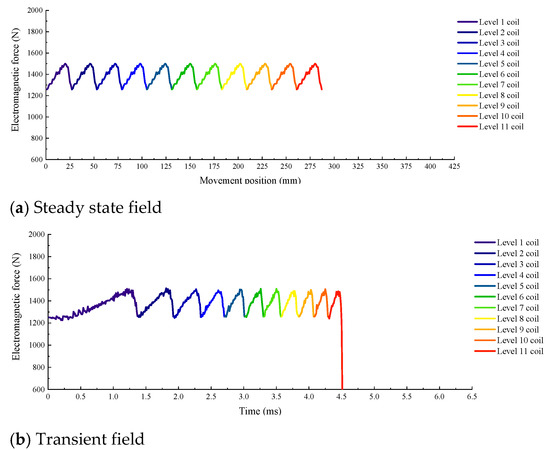
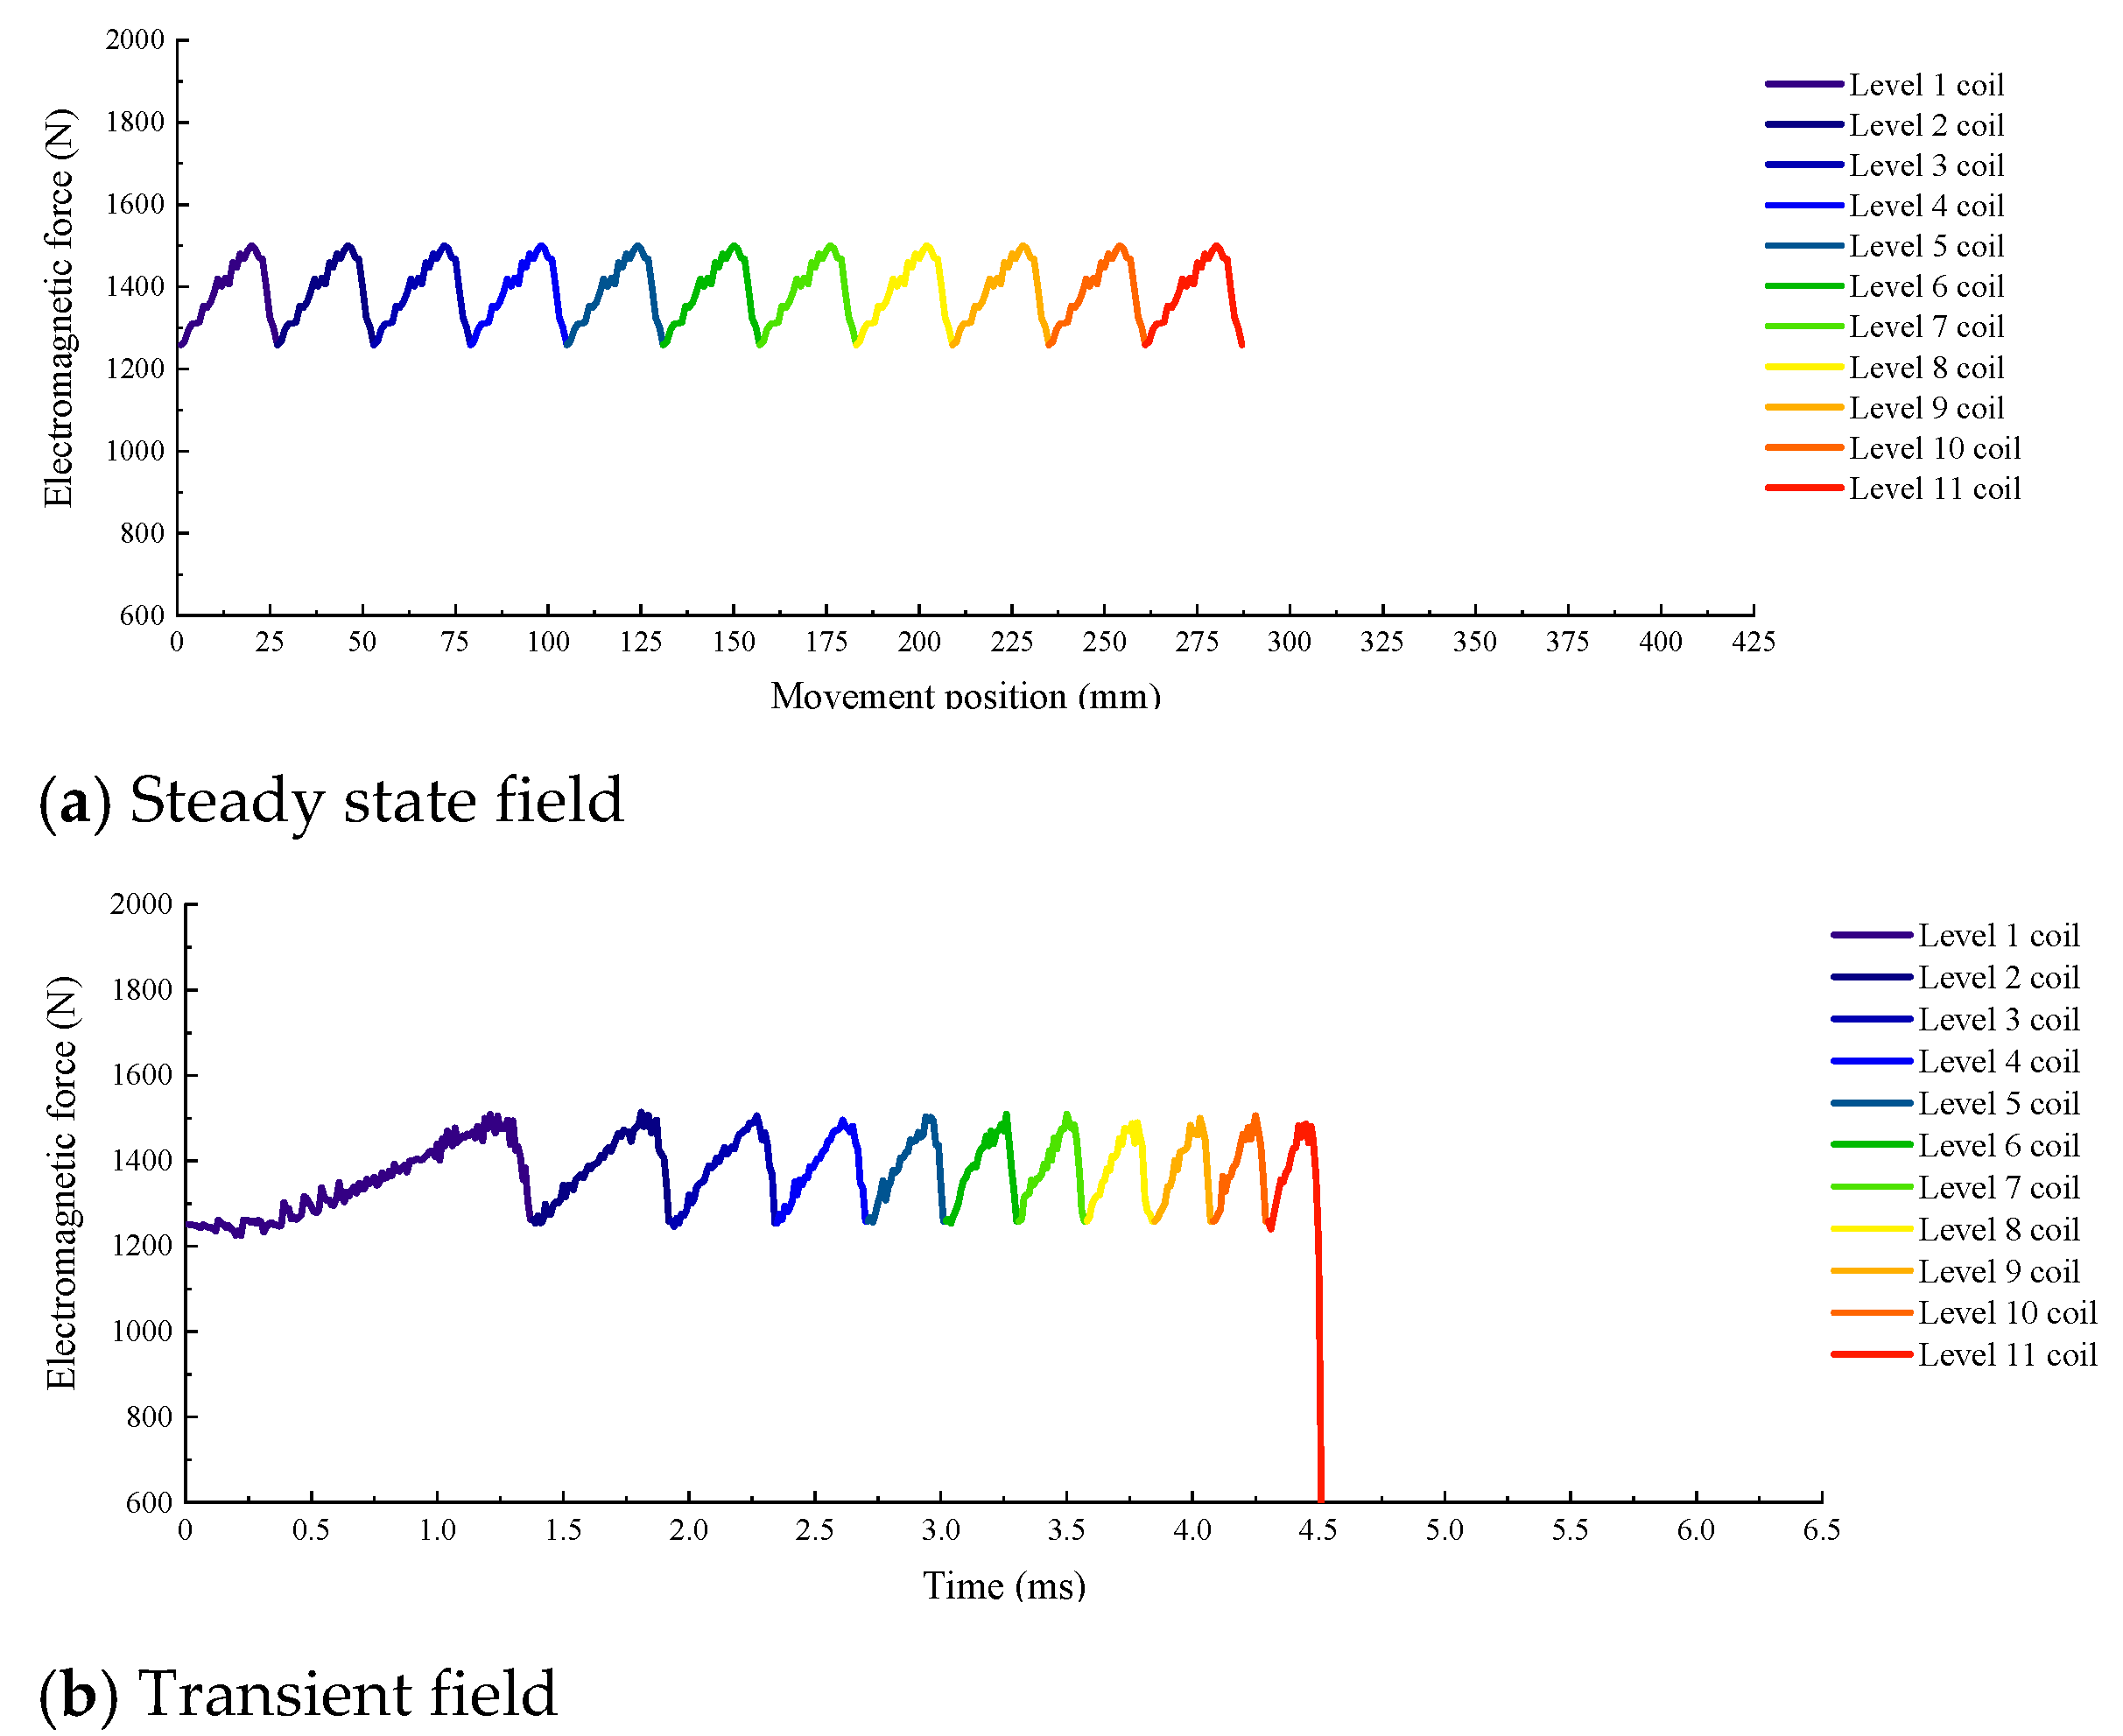
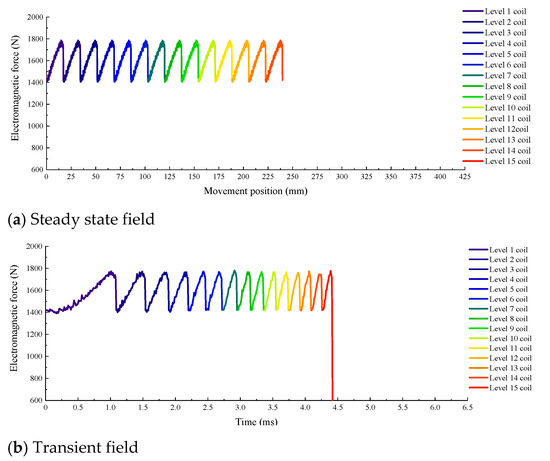
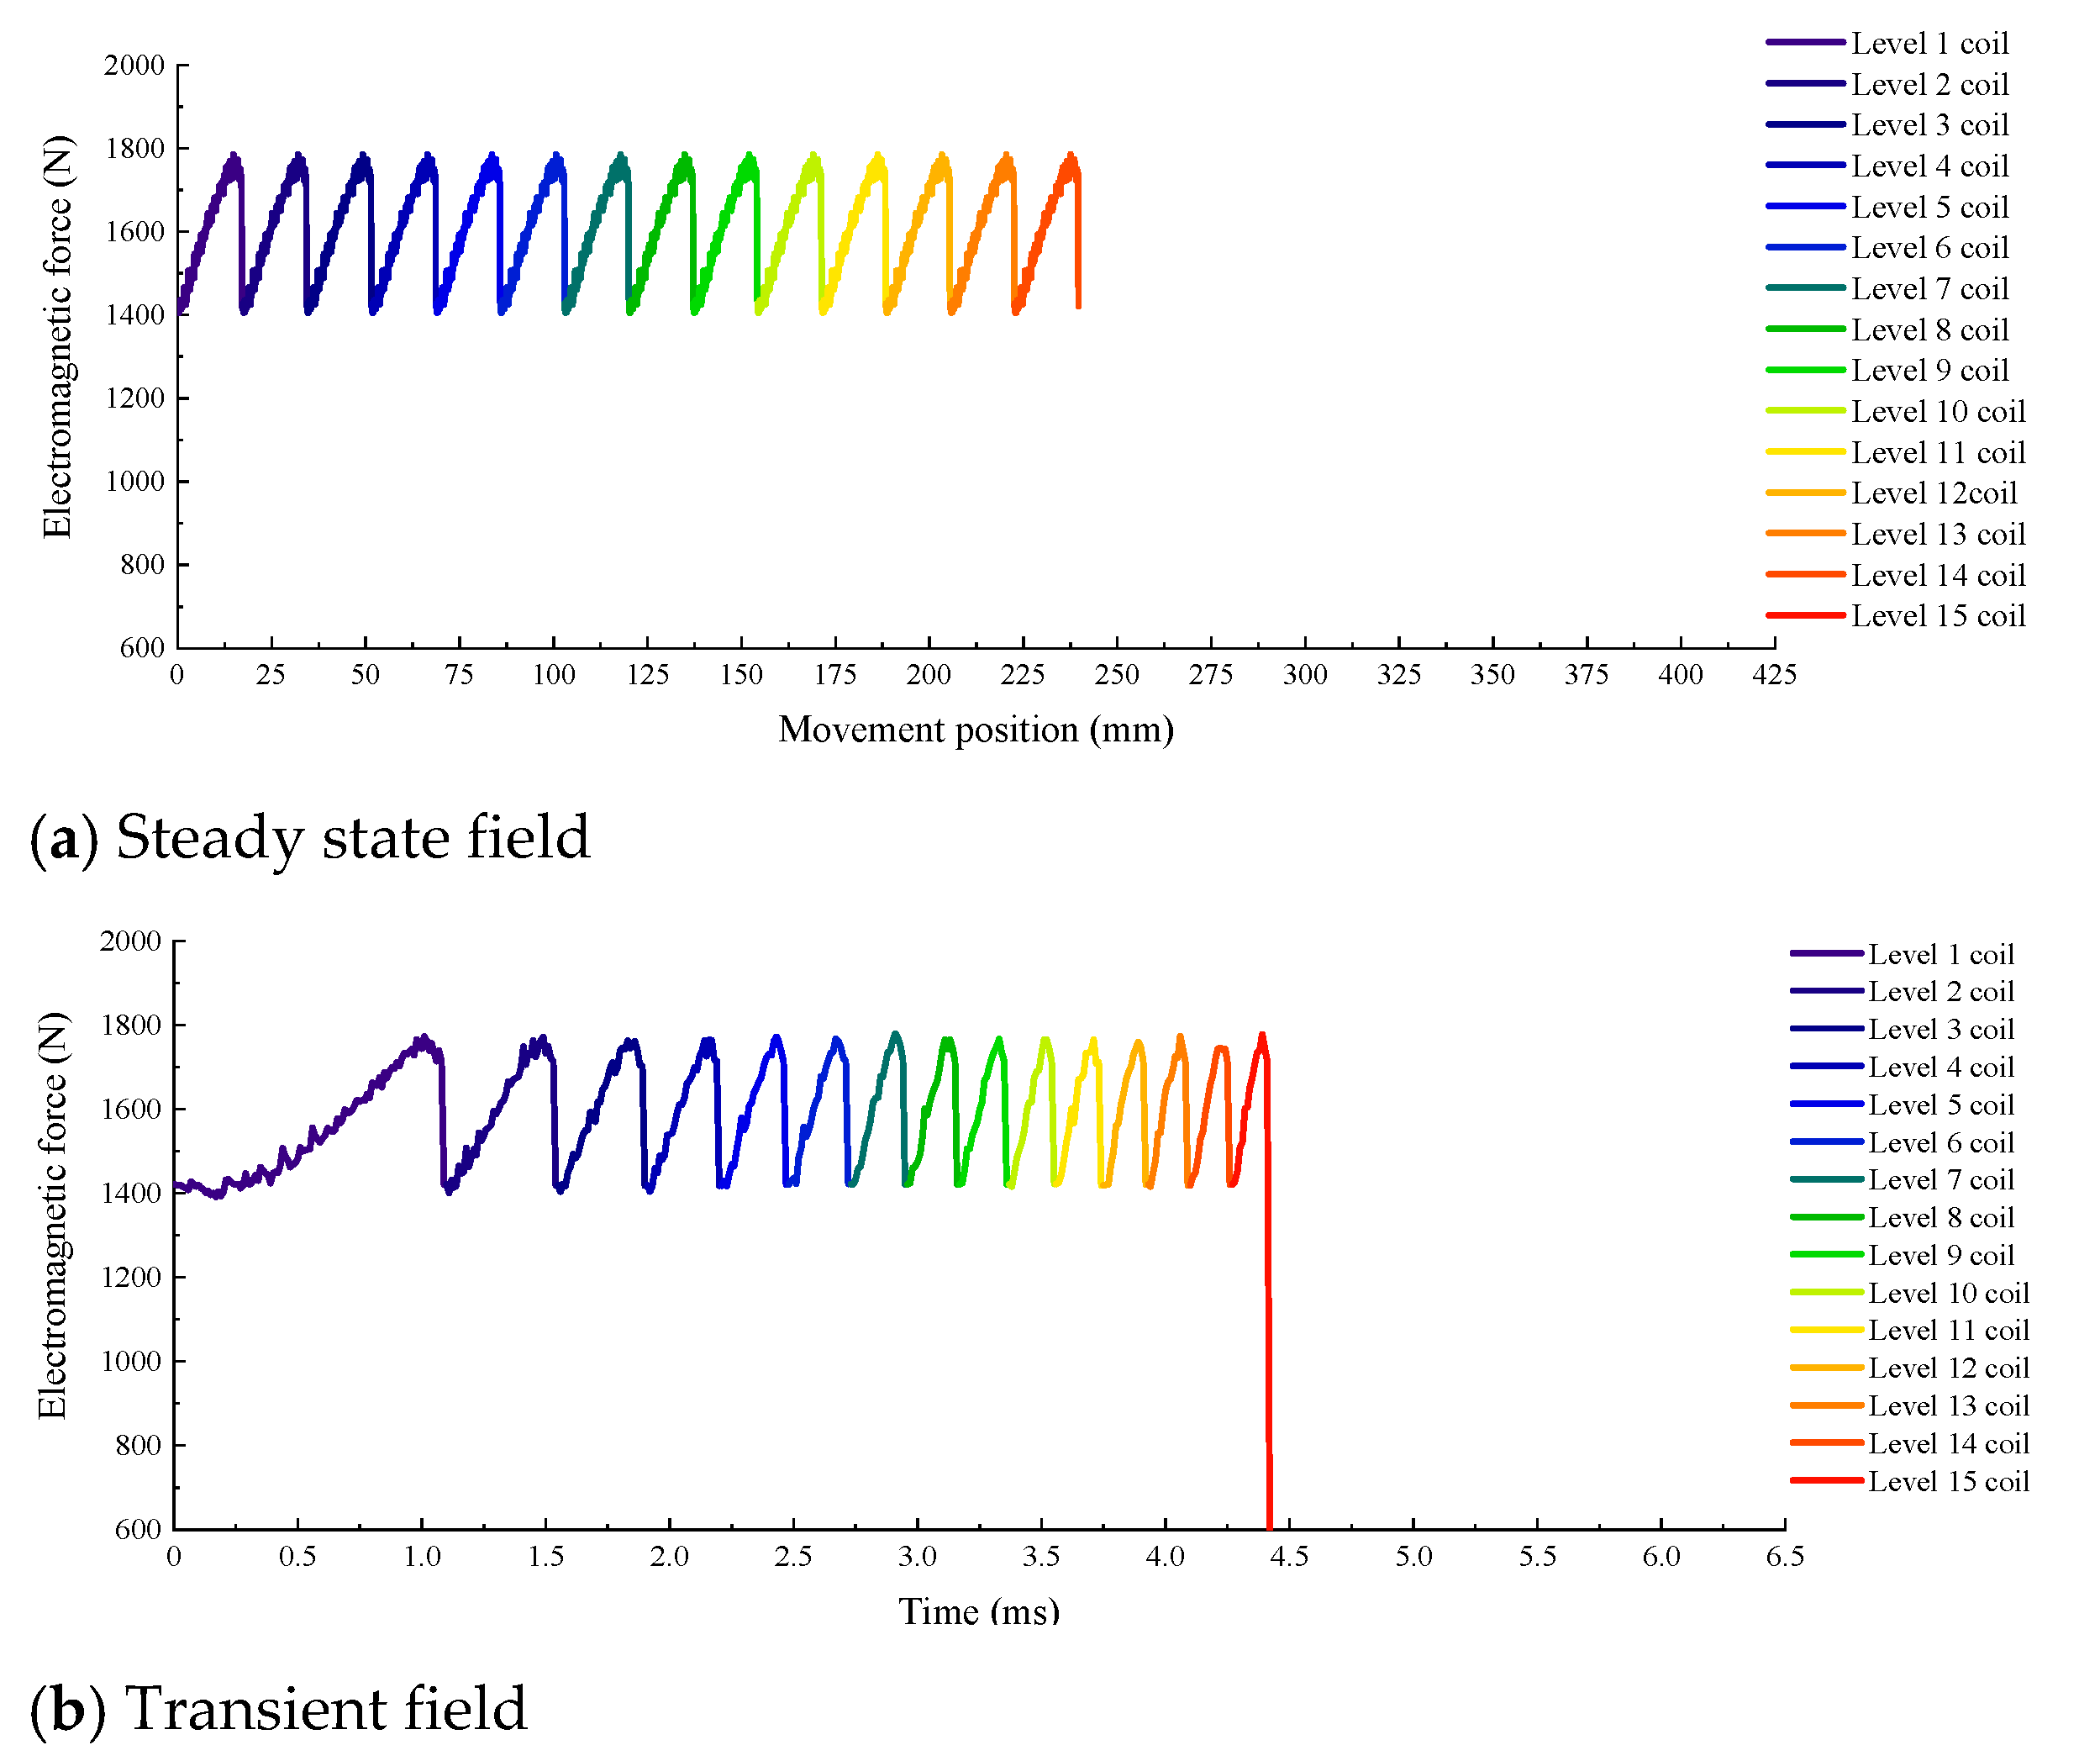
The combined coil length is further optimized and improved on the basis of 45 mm. The steady state and transient forces of the weft clamp in the combined coil when the simulation parameters of the coil length are 30 mm and 15 mm are shown in Figure 12 and Figure 13, respectively. Compared with Figure 10, it can be seen that the steady state field electromagnetic force of the 30 mm and 15 mm combined coils also exhibits periodic changes. In the transient field, the speed becomes faster and faster at the same acceleration distance, and the curve width becomes narrower and narrower, that is, the time spent in each level of acceleration becomes shorter and shorter. In terms of electromagnetic force, the range of electromagnetic force of 30 mm segmented coils is 1200~1500 N, with an average force of 1400 N; and the electromagnetic force of 15 mm segmented coils ranges from 1400 to 1800 N, with an average force of 1600 N. The design principle of the segmented combined acceleration method is to use the weft clamp to perform continuous high-speed acceleration in the area of the coil with the largest electromagnetic force. According to this concept, the smaller the coil length, the better the combination effect. However, considering the requirements of the manufacturing process of a 5 mm long coil, the coil wire diameter is 1 mm, and the addition of the outer yoke will increase the manufacturing cost and space utilization. The drastically reduced rate goes against the original intention of optimization.
Figure 12.
The electromagnetic force of 30 mm continuous acceleration coil.
Figure 13.
The electromagnetic force of 15 mm continuous acceleration coil.
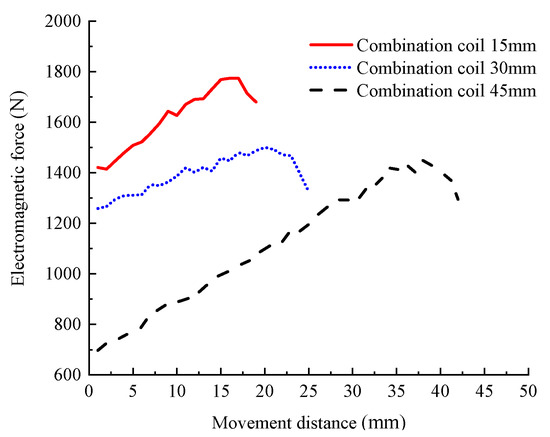
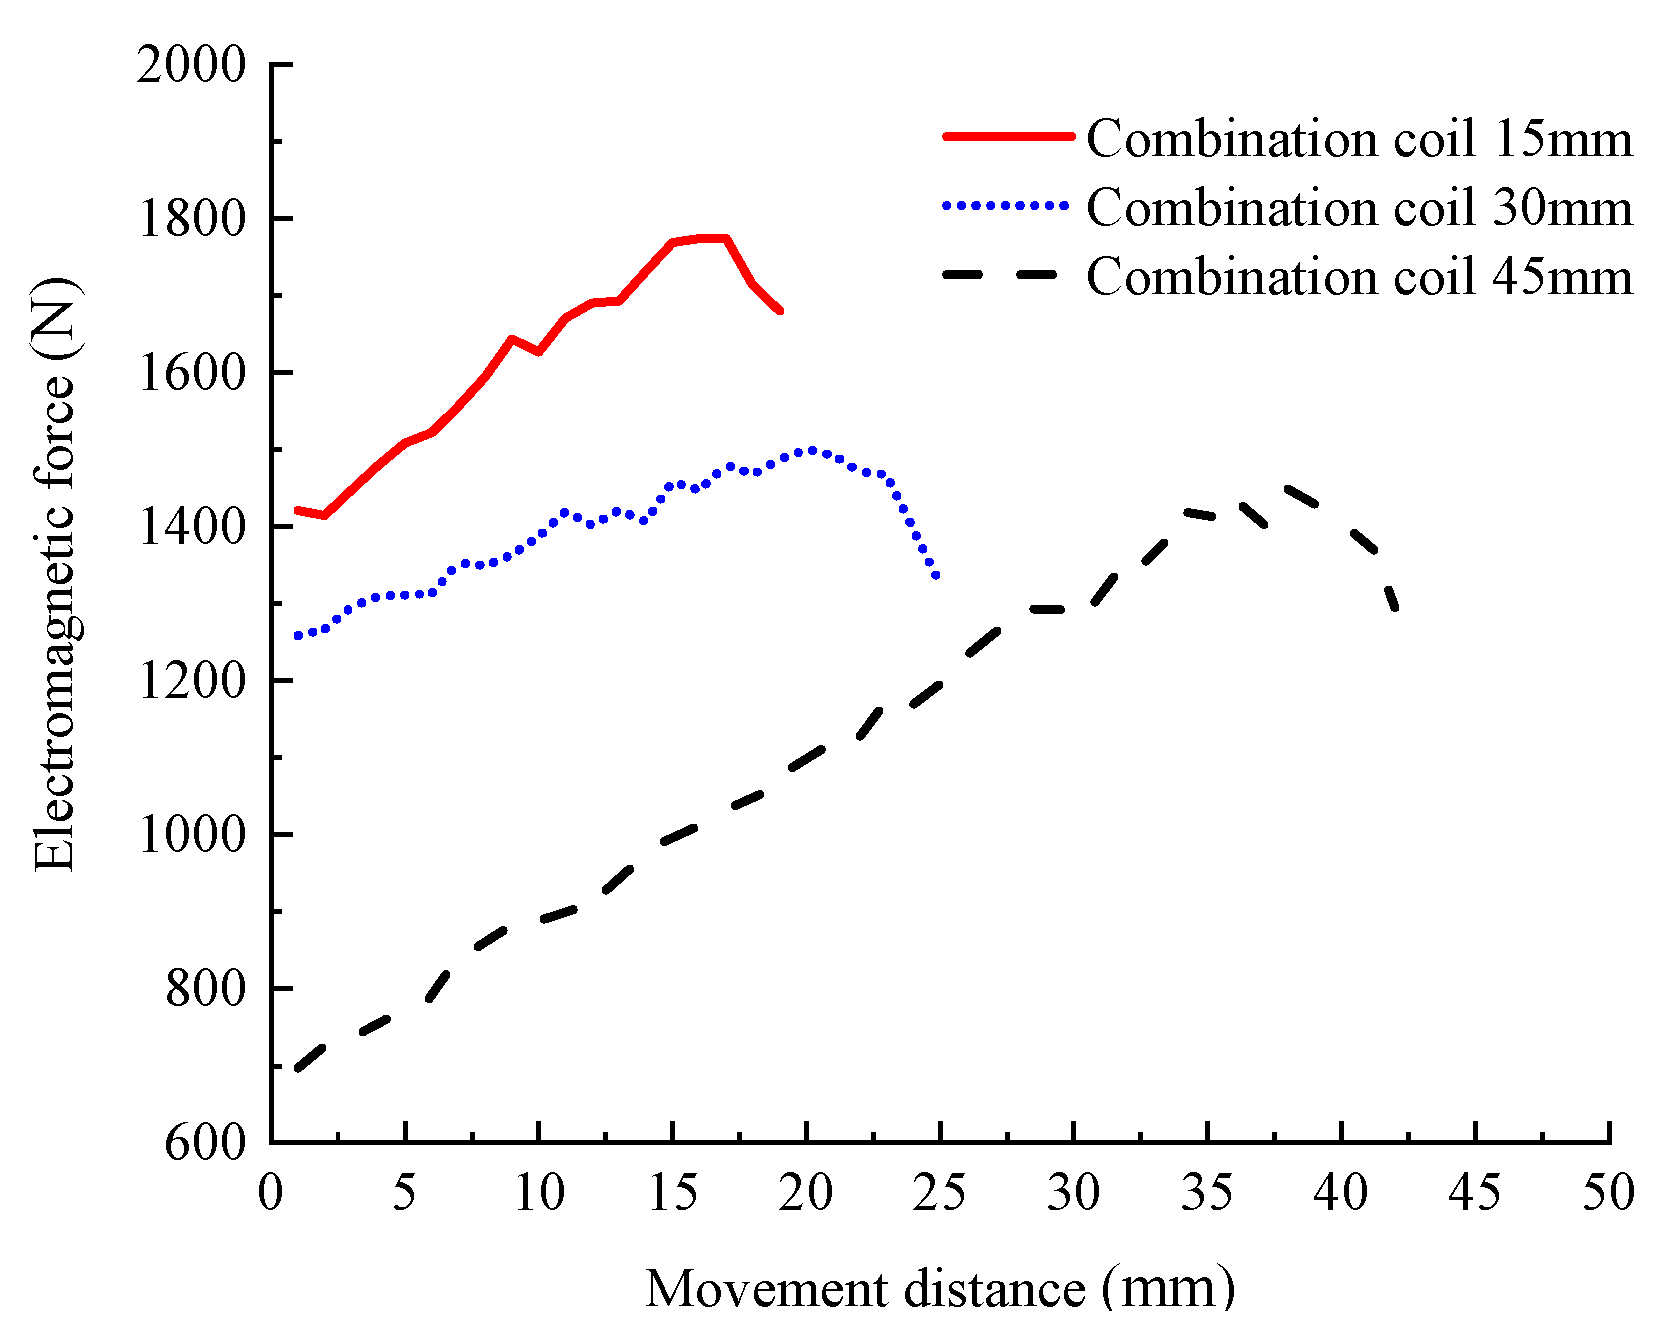
In the steady state, the electromagnetic force of the three different lengths of segmented coils is shown in Figure 14. The electromagnetic force increases continuously from the starting point and decreases near the end of the coil. The electromagnetic force of the 15 mm combined coil shows a downward trend after the moving distance of 15 mm, because the thickness of the yokes of the two adjacent coils reaches 4 mm, and each coil had a yoke length of 2 mm in the axial direction. The reason for the small coil length, the increased difficulty of the production process, and the influence on control requirements and electromagnetic force cannot be ignored. The electromagnetic force of the 30 mm and 45 mm combined coils reaches its peak at about 20 mm and 40 mm, and the electromagnetic force begins to decrease. This is consistent with the peak electromagnetic force of the single-stage 90 mm coil at 75~85 mm. The peak electromagnetic force of the 30 mm combined coil appears near 20 mm, which is equivalent to the peak of the 3-level combined coil appearing near 80 mm; the peak of the electromagnetic force of the 45 mm combined coil appears near 40 mm, which is equivalent to the peak of the 2-level combined coil near 85 mm.
Figure 14.
Comparison of steady state electromagnetic forces of combined coils with different lengths.
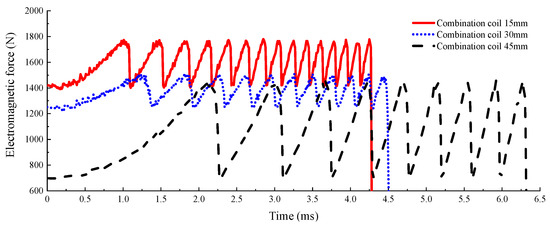
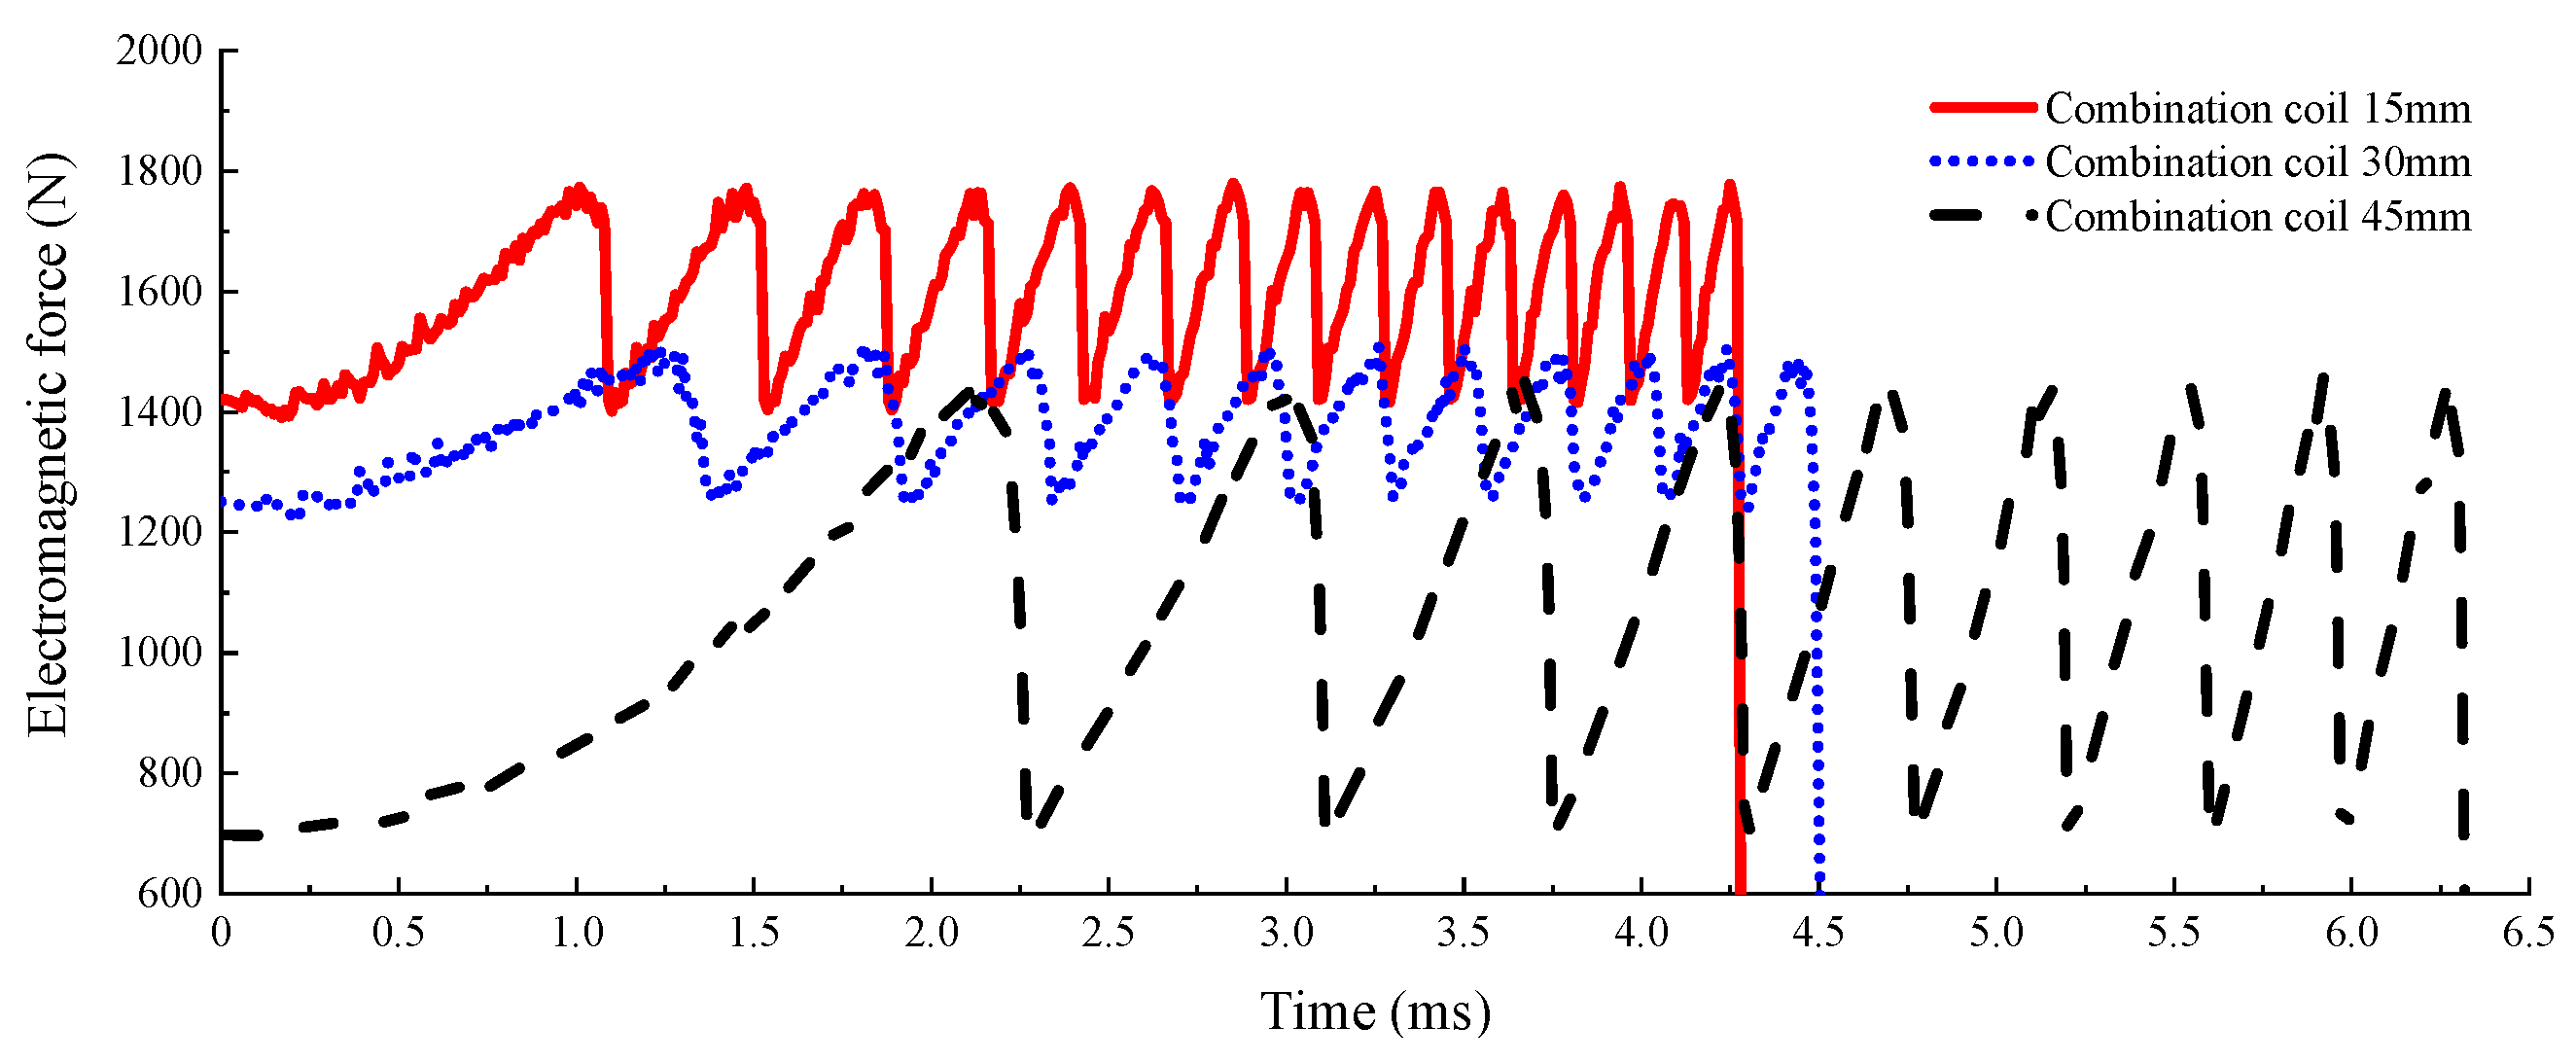
Figure 15 shows that the electromagnetic force fluctuation range and peak size in the transient state are consistent with the steady state. The difference lies in the acceleration time and the number of accelerations (coil stages). Similarly, speeding up to 125 m/s required for export express delivery requires 9 levels for the combined coil with a length of 45 mm; 30 mm is 2 levels more than 45 mm; and 15 mm requires 6 levels more than 45 mm. Because the stepwise-combined acceleration is repeatedly accelerated by the highest level of the electromagnetic force of the superimposed magnetic field—despite the electromagnetic force remaining at the highest band its working distance is relatively short —the shorter the coil length, the more levels required. As shown in Table 3, in terms of total coil length, segmented combined coils are shorter. Among them, the thickness of the combined coil yoke is 1 mm, two sections, and the total yoke thickness is 2 mm.
Figure 15.
Comparison curve of electromagnetic force of combined coils with different lengths.
Table 3.
Coil parameters of different combinations.
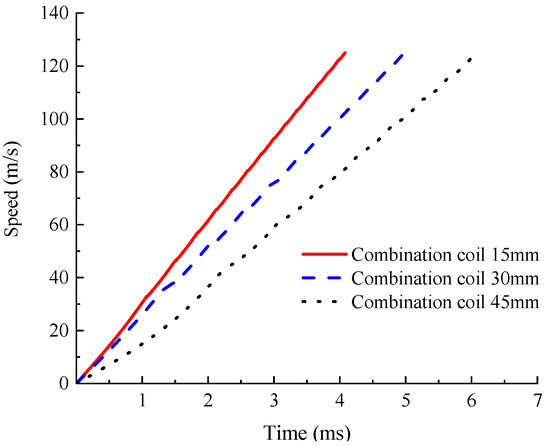
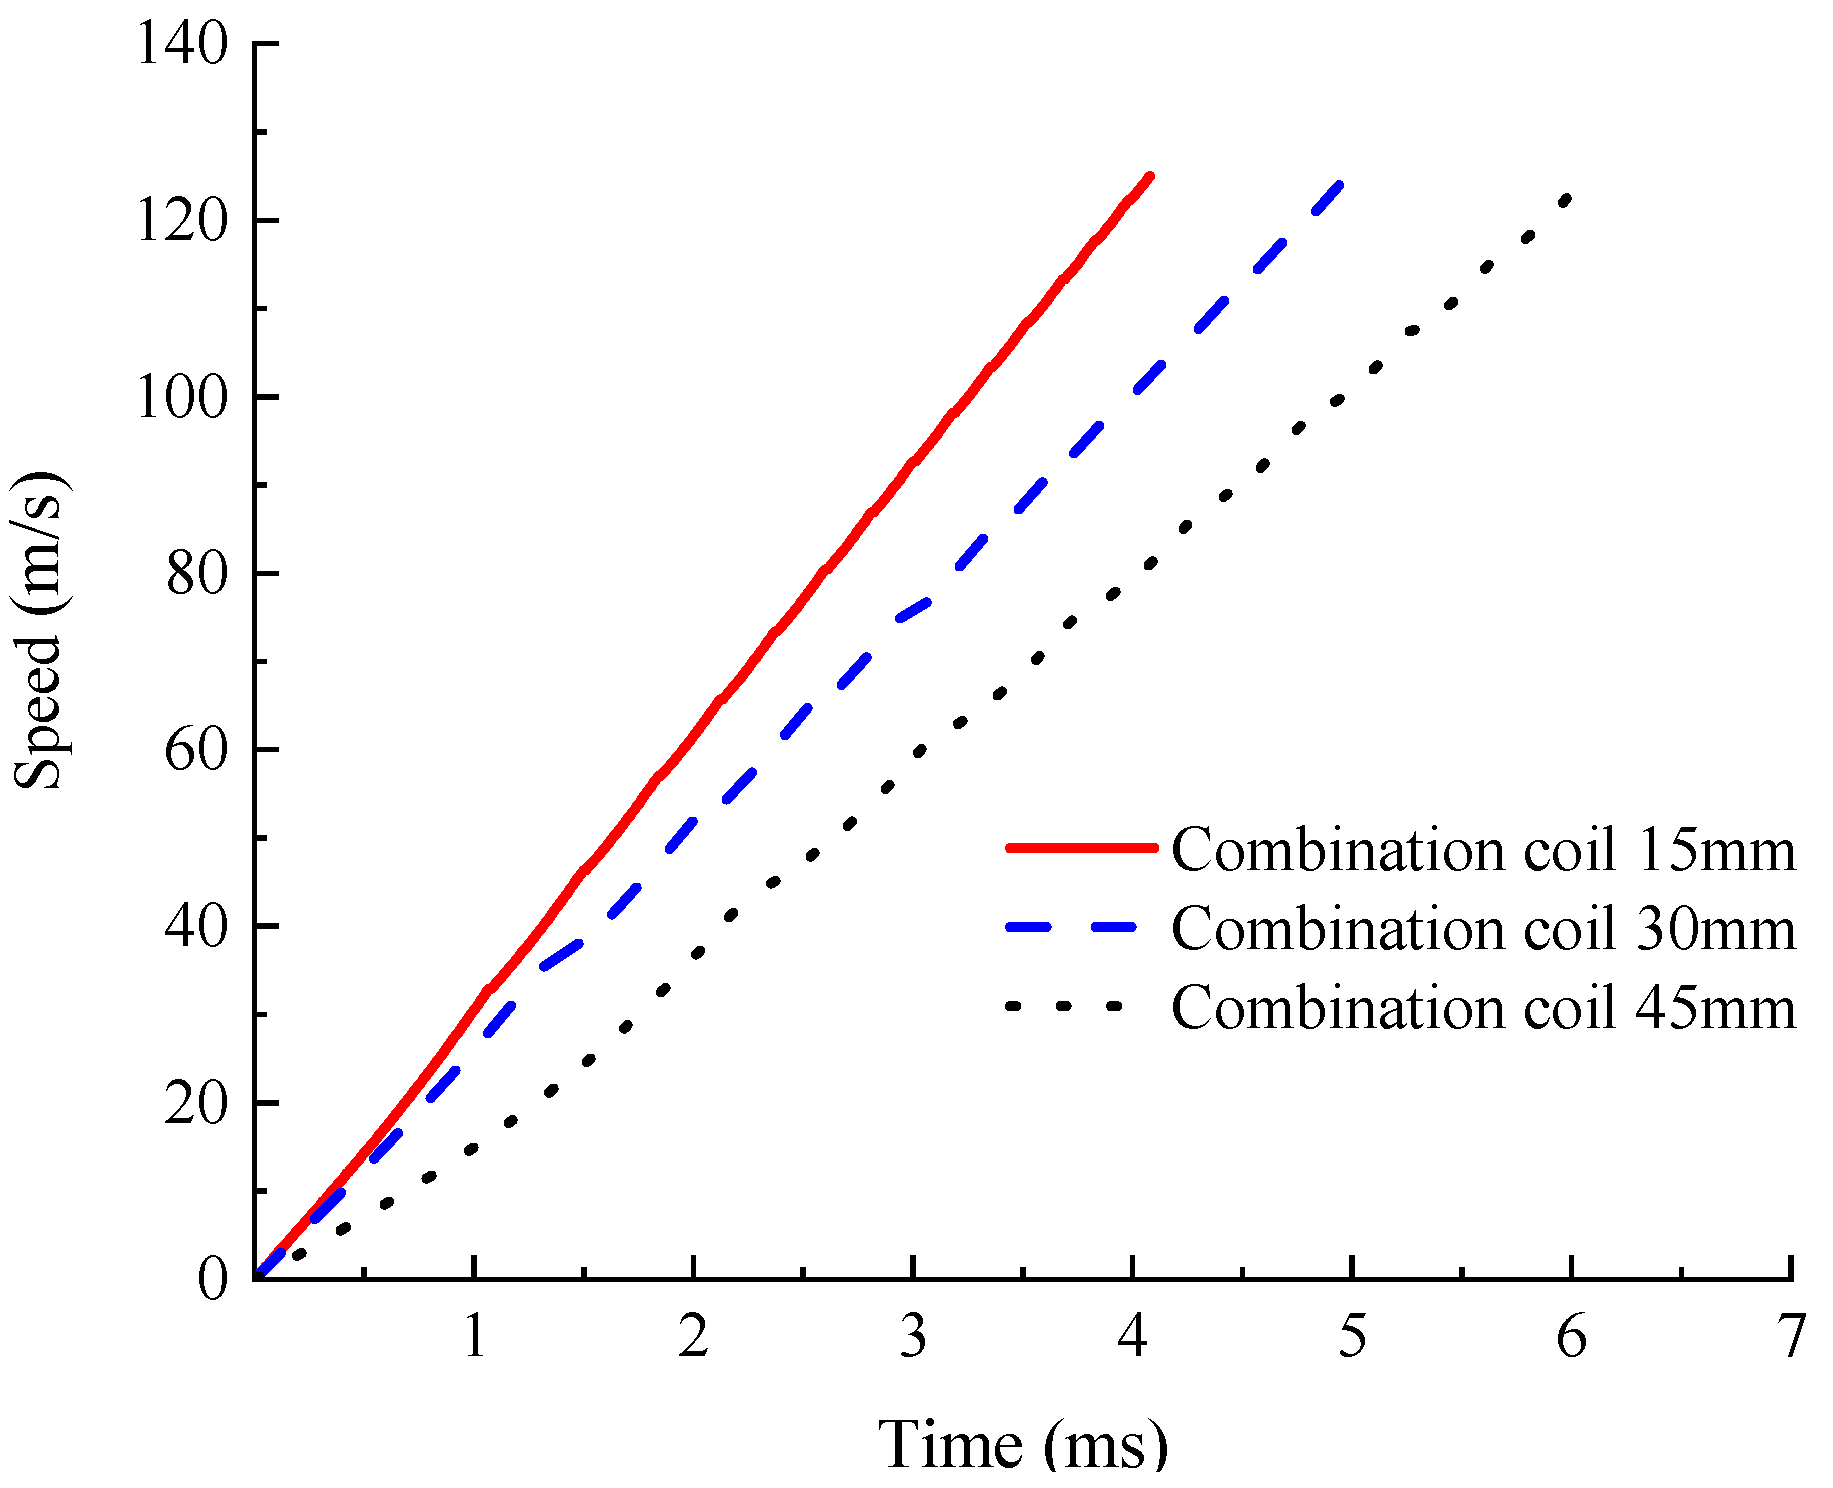
The peak electromagnetic force of the combined coils of different lengths fluctuates by several hundred Newtons, which is mainly due to the influence of the coil yoke. The combined coil yoke is made of pure iron, and the thickness of the yoke cannot be ignored when the combined coil length is small enough. The magnetized internal yoke further increases the electromagnetic force as the iron core is added to the energized coil. Another difference is the total acceleration time of the combined coil. Combining Figure 15 and Figure 16, we can see that the shortest time spent by the 15 mm combined coil is about 4.3 ms, the 30 mm combined coil has an acceleration time of about 4.5 ms, and the 45 mm combined coil has the longest time, about 6.3 ms. It can also be seen from the speed-time curve that the slope of the curve—that is, the speed ratio increase coefficient of 15 mm—is the largest, followed by 30 mm. Meanwhile, 45 mm is the smallest, indicating that the acceleration and magnetic force of 15 mm is the largest. From the perspective of acceleration time and processing technology, the 30 mm combined coil is a better choice. From the perspective of the acceleration effect and the acceleration time, it is not particularly different to the 15 mm combined coil. The electromagnetic force of the 30 mm combined coil is better than that of the 15 mm combined coil. The entire acceleration process is subject to a constant acceleration effect of approximately 1400 N.
Figure 16.
Speed comparison curve of different length combined coils.
5. Conclusions
In this paper, the electromagnetic weft insertion launcher of the extra-large width automatic loom is further optimized. Based on the single-stage electromagnetic weft insertion and the multi-stage intermittent electromagnetic weft insertion, a new segmented combined continuous acceleration electromagnetic weft insertion scheme is proposed. The segmented combined structure performance optimization design is carried out on the acceleration coil. Calculation models for electromagnetic force and theoretical velocity analysis have been established. The static and transient simulation analysis of magnetic field motion is carried out for segmented combined coils of different lengths. The segmented combined electromagnetic launch method shortens the overall length of the acceleration coil. Compared with the 812 mm total length of the multi-stage discontinuous 90 mm acceleration coil, the total length of the segmented combined acceleration coil is shortened by nearly half. The total length of the segmented combined 45 mm, 30 mm, and 15 mm combined coils are: 470 mm, 416 mm, and 340 mm, respectively. The simulation results show that under the premise of the same exit speed of 125 m/s, the combined coil takes a shorter time. The electromagnetic force peak range of the acceleration coil should be sought and used in order to improve the stability and uniformity of the force during the entire acceleration process. The launch performance of the electromagnetic weft insertion mechanism is improved by the method of continuous acceleration by segment combination. This paper lays a foundation for further research on the electromagnetic weft insertion combined coil of the extra-large width automatic loom.
6. Patents
The content of this article has applied for a Chinese invention patent and has been authorized: a sectional combined relay magnetic drive reducer and its deceleration method [P]. ZL201911166172.5.
Author Contributions
Conceptualization, Q.X. and S.M.; methodology, Q.X.; software, X.C.; validation, Q.X., S.M., X.C. and Y.H.; formal analysis, Z.C.; investigation, F.M.; resources, Q.X.; data curation, X.C.; writing—original draft preparation, X.C.; writing—review and editing, X.C.; visualization, Q.X.; supervision, Q.X.; project administration, Q.X.; funding acquisition, S.M. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the Hubei Province Natural Science Foundation of China (Grant No. 2020CFB769), State Key Laboratory of New Textile Materials and Advanced Processing Technologies (Grant No. FZ2020008), National Science Foundation of China (Grant Nos. 51541503, 50775165, 51775389). Hubei Key Laboratory of Digital Textile Equipment (Grant No. KDTL2020007).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Not applicable.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Khan, S.; Hosen, M.M. Arduino controlled filling yarn presenter of modern rapier loom. Am. Sci. Res. J. Eng. Technol. Sci. 2021, 76, 84–100. [Google Scholar]
- Osman, A.; Delcour, L.; Hertens, I.; Vierendeels, J.; Degroote, J. Toward three-dimensional modeling of the interaction between the air flow and a clamped–free yarn inside the main nozzle of an air jet loom. Text. Res. J. 2019, 89, 914–925. [Google Scholar] [CrossRef] [Scilit]
- Juraeva, M.; Song, D.J.; Kang, D.J. Computational optimization approach to design a water-jet nozzle for a water-jet loom using the design of experiment method. J. Mech. Sci. Technol. 2019, 33, 631–637. [Google Scholar] [CrossRef] [Scilit]
- Sekercioglu, T. Failure Analysis of torsion bar of projectile weaving machine. J. Fail. Anal. Prev. 2010, 10, 363–366. [Google Scholar] [CrossRef] [Scilit]
- Chen, Y.D.; Zhao, C.C.; Yin, J.Q.; Cheng, Y.F.; Gu, J.Y. Structural design and flow field analysis of a new type of weft insertion piece for air-jet loom. Basic Sci. J. Text. Univ. 2020, 33, 59–63. [Google Scholar]
- Zhou, R.; Ma, Y.X.; Li, Y.L.; Hu, J.Y.; Zhang, R.Y.; Du, W.P. The design of a new circular orbit method for weft insertion. Ind. Text. 2017, 35, 37–41. [Google Scholar]
- Luo, S.M.; Zhang, B.; Tian, L.; Ma, Z.H. Study of a electromagnetic weft insertion in textile machine. Adv. Mater. Res. 2012, 591, 498–501. [Google Scholar] [CrossRef] [Scilit]
- Zhang, M.Y.; Liu, Y.; Zhou, P.; Li, F. Viewing the development of US electromagnetic launch technology from patents. Fly. Missile 2017, 9, 36–40. [Google Scholar] [CrossRef]
- Hamsathvanie, K. Electromagnetic picking of loom. Silk 1977, 11, 42–48. [Google Scholar]
- Owlia, E.; Mirjalili, S.A.; Shahnazari, M. Design and modeling of an electromagnetic launcher for weft insertion system. Text. Res. J. 2019, 89, 834–844. [Google Scholar] [CrossRef] [Scilit]
- Owlia, E.; Mirjalili, S.A. Simulation of the electromagnetic weft insertion system by adaptive neuro fuzzy interface system. J. Text. Inst. 2021, 112, 1359–1366. [Google Scholar] [CrossRef] [Scilit]
- Jordan, J.V.; Kemper, M.; Renkens, W.; Gloy, Y.S. Magnetic weft insertion for weaving machines. Text. Res. J. 2018, 88, 1677–1685. [Google Scholar] [CrossRef] [Scilit]
- MirjaliliI, S.A. Design and Manufacturing an Electromagnetic Projectile Mechanism for Weft Insertion in a Loom. In Proceedings of the Textile Institute 83rd World Conference, Shanghai, China, 23–27 May 2004; pp. 1148–1152. [Google Scholar]
- Qiao, X.; Shunqi, M.; Xiaoyu, Y.; Islam, M.M.; Zhen, C.; Shaojun, W.; Zhiming, Z. Analysis of the magnetic field and electromagnetic force of a non-striking weft insertion system for super broad-width looms, based on an electromagnetic launcher. Text. Res. J. 2019, 89, 4620–4631. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.; Yan, R.; Duan, Y.; Qiu, J.; Chen, T.; Ma, H. An environmental-friendly tannic acid/Zn conversion film with a good corrosion protection for iron. Surf. Interfaces 2021, 24, 101078. [Google Scholar] [CrossRef] [Scilit]
- Migal, Y.F.; Kolesnikov, V.I.; Shishiyanu, D.N. Computer simulation of TiAlN coatings and its analogues on iron surface. In Proceedings of the IOP Conference Series: Materials Science and Engineering, Sanya, China, 12–14 November 2021; Volume 1029, p. 012057. [Google Scholar]
- Weeraratne, A.I.; Hewa-Rahinduwage, C.C.; Luo, L.; Verani, C.N. Electrochemical quantification of corrosion mitigation on iron surfaces with Gallium (III) and Zinc (II) Metallosurfactants. Langmuir 2020, 36, 14173–14180. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Fang, M.N.; Wei, F.Y.; Chen, X. Magnetic field distribution characteristics and applications of solenoids. J. Chang. Univ. Posts Telecommun. 1994, 12, 11–14. [Google Scholar]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).