


Abstract
Piezoelectric actuators are widely used in ultra-precision micropositioning systems, but their inherent rate-dependent hysteresis nonlinearities severely degrade dynamic positioning accuracy. This paper proposes an enhanced rate-dependent generalized Prandtl–Ishlinskii (ERGPI) model that accurately captures rate-dependent hysteresis evolution and substantially improves the modeling of dynamic nonlinear responses. To efficiently obtain reliable model parameters, an improved dynamic adaptive differential evolution algorithm (ID-LSHADE) is developed, which accelerates convergence without sacrificing identification accuracy. The proposed ERGPI model achieves superior rate-dependent hysteresis modeling performance with negligible parameter overhead: the relative root-mean-square error and relative maximum error are up to 1.04% and 2.08%, respectively, outperforming the traditional GPI model over a wide frequency range. Based on the well-identified ERGPI model, a direct inverse feedforward compensation strategy is further constructed to suppress hysteresis-induced positioning errors. Experimental results demonstrate that the combined modeling and identification framework accurately characterizes the asymmetric and rate-dependent hysteresis of piezoelectric actuators with high efficiency and low parametric complexity. Broadband hysteresis compensation and trajectory tracking experiments further verify the effectiveness of the proposed feedforward scheme in mitigating hysteresis nonlinearities and improving dynamic positioning performance. This study provides an effective alternative for high-precision dynamic control of piezoelectric micropositioning systems.
1. Introduction
With high positioning accuracy, fast dynamic response and large output force, piezoelectric actuators have emerged as core micro-nano driving devices and are widely employed in precision positioning systems, biomedical engineering, and aerospace engineering [1,2,3,4]. Despite their prominent advantages, piezoelectric actuators have inherent technical limitations in practical engineering applications. They can generate considerable compressive force but cannot withstand tensile load, thereby requiring preloading structures for normal operation. In addition, piezoelectric actuators exhibit obvious creep behavior, where their output displacement drifts gradually over time under constant input voltage. More critically, severe hysteresis nonlinearity exists in piezoelectric actuation systems, presenting a non-unique mapping between input voltage and output displacement, where a single input value may correspond to multiple displacement outputs. Hysteresis-induced errors can occupy 10–15% of the full stroke, significantly deteriorating positioning precision, undermining system stability and restricting the effective control bandwidth. Accordingly, comprehensively characterizing piezoelectric hysteresis behaviors is crucial for enhancing the control accuracy and practical applicability of piezoelectric actuators in engineering scenarios.
Extensive research has focused on mitigating the adverse impacts of piezoelectric hysteresis, among which accurate and efficient hysteresis modeling serves as the most fundamental and effective technical approach. Current hysteresis modeling strategies can be broadly classified into physical and phenomenological categories. Representative physical models include the Jiles–Atherton [5] model for ferromagnetic hysteresis. Nevertheless, their intricate physical mechanisms and high computational overhead greatly restrict their applicability to real-time controller design. In comparison, phenomenological models establish mathematical formulations based on macroscopic input–output hysteresis characteristics, without requiring in-depth exploration of the intrinsic physical properties of piezoelectric materials, thereby exhibiting superior practicability and universality. For this reason, phenomenological modeling has emerged as the mainstream technique for piezoelectric hysteresis characterization and is adopted in this study. Typical phenomenological models consist of the Preisach model [6,7], Prandtl-Ishlinskii (P-I) model [8,9], Krasnosel’skii–Pokrovkii (KP) model [10], Bouc–Wen model [11,12], Dahl model [13], Duhem model [14,15], and backlash-like model [16]. These models can be further categorized into differential equation-based and operator-based frameworks, as well as rate-independent and rate-dependent types in accordance with their frequency response properties.
The Prandtl-Ishlinskii (P-I) model is one of the most widely adopted hysteresis models due to its simple structure and low computational consumption. Initially proposed by Prandtl in 1928 to describe elasto-plastic strain-hardening phenomena, this model was further refined by Ishlinskii in 1944. Nevertheless, the classical P-I model is intrinsically symmetric and rate-independent, making it incapable of accurately characterizing the asymmetric and frequency-dependent hysteresis behaviors of practical piezoelectric actuators. To address these limitations, Gu et al. established a modified P-I model by introducing polynomial functions of input signals to fit asymmetric hysteresis, and Yang et al. further constructed rate-dependent frameworks via employing dynamic envelope functions [17,18]. Gan et al. established a generalized rate-dependent P-I model by incorporating frequency-dependent functions of input signals [19]. Zhi et al. proposed a piecewise modified Prandtl-Ishlinskii (PMPI) model with segmented nonlinear envelope functions [20]. Wang et al. introduced delay operators to capture dynamic rate-dependent hysteresis features [21,22]. Moreover, Al Janaideh et al. proposed a generalized Prandtl-Ishlinskii (GPI) model, which realizes asymmetric hysteresis modeling via improved play operators and describes rate-dependent characteristics by adopting rate-related dynamic threshold functions [23,24]. Further optimization of the GPI model’s rate-dependent performance was achieved by Zhu et al., who replaced the model’s initial component with a voltage change rate function [25]. Given the superior asymmetric fitting capability of the GPI model, this study develops an enhanced framework based on GPI to improve its rate-dependent hysteresis characterization accuracy.
Hysteresis modeling accuracy depends on both model structural design and parameter identification performance, so a high-performance optimization algorithm is indispensable for high-fidelity hysteresis characterization [26]. Traditional identification methods such as the least squares method exhibit poor optimization performance for multi-parameter nonlinear hysteresis systems. Heuristic optimization algorithms, including genetic algorithm (GA) [27], particle swarm optimization (PSO) [28,29], and differential evolution (DE) [30], are widely used for nonlinear system parameter identification. However, GA suffers from slow convergence speed, while PSO is prone to local optimum trapping when solving high-dimensional multi-modal optimization problems [31,32]. As a robust heuristic algorithm, DE has attracted extensive attention owing to its simple structure and stable optimization performance. To further improve its search ability, multiple improved DE variants have been proposed. Among them, the linear population size reduction success-history-based adaptive differential evolution (L-SHADE) algorithm integrates adaptive parameter adjustment and linear population size reduction strategies, achieving better performance in continuous optimization and parameter identification than conventional DE methods [33]. Nevertheless, L-SHADE suffers from gradual loss of population diversity, which may slow down the convergence rate and limit the parameter identification precision for wide-range frequency dynamic hysteresis modeling of piezoelectric actuators. To further enhance the convergence efficiency and parameter identification precision of the L-SHADE algorithm for wide-frequency piezoelectric hysteresis identification tasks, this work develops an improved dynamic adaptive L-SHADE (ID-LSHADE) algorithm.
Once a hysteresis model has been established, feedforward compensation can be implemented for piezoelectric actuators by deriving the analytical inverse of the identified model or by directly identifying an inverse model from experimental data. This approach does not require additional measurement devices for real-time feedback; however, its performance depends strongly on the accuracy of the established hysteresis model and its inverse. To improve control robustness and mitigate the effects of system dynamics, advanced closed-loop control strategies represent another important research direction beyond feedforward compensation. Accordingly, various feedback control methods have been developed for piezoelectric micropositioning systems [34,35,36].
Motivated by the above-mentioned limitations, this work develops an enhanced rate-dependent generalized Prandtl-Ishlinskii (ERGPI) hysteresis model. By applying independent weighted envelope processing for ascending and descending hysteresis branches, the ERGPI model introduces only four extra identifiable parameters relative to the conventional GPI model and achieves accurate characterization of asymmetric rate-dependent hysteresis at low computational cost. Furthermore, an improved ID-LSHADE algorithm is proposed with multi-mutation adaptive competition and individual evolutionary momentum strategies. The algorithm improves convergence efficiency while maintaining competitive identification performance, which supports the ERGPI model for high-accuracy hysteresis modeling of piezoelectric actuators under broadband excitation. A feedforward compensator based on the ERGPI model is subsequently designed and experimentally validated. The experimental results demonstrate that the proposed compensator can effectively suppress hysteresis nonlinearity over a broad frequency range.
The remainder of this paper is structured as follows. Section 2 reviews the theoretical fundamentals of the classical P-I and GPI models and formulates the proposed ERGPI hysteresis model. Section 3 elaborates the principle and implementation procedure of the ID-LSHADE algorithm for parameter identification. Section 4 details the design scheme of the direct inverse hysteresis compensator. Section 5 presents the experimental platform setup and comprehensively validates the accuracy of the proposed hysteresis model, the efficiency of the identification algorithm, and the compensation performance of the feedforward compensator. Finally, Section 6 summarizes the core findings of this work and outlines potential directions for future research.
2. Hysteresis Modeling
Conventional and modified Prandtl-Ishlinskii (P-I) hysteresis models are inherently designed for rate-independent hysteresis characterization, yet their modeling accuracy degrades significantly when capturing rate-dependent hysteresis responses. For this reason, the development of high-precision rate-dependent hysteresis models has become a pivotal research direction in piezoelectric hysteresis modeling. The enhanced rate-dependent generalized Prandtl-Ishlinskii (ERGPI) model proposed in this study is constructed based on the generalized P-I (GPI) model. Accordingly, the classical P-I and GPI models are briefly reviewed prior to the detailed elaboration of the proposed ERGPI model.
2.1. Classical P-I Model
The P-I model consists of a series of elementary stop or play operators. For hysteresis modeling of piezoelectric actuators, the play operator is selected as the fundamental unit. Its counterclockwise response characteristic is highly consistent with the hysteresis trajectory of piezoelectric actuators, making it well-suited for piezoelectric hysteresis fitting. For any piecewise monotonic and continuous input function v(t) defined over the time interval [0, tE], the mathematical formulation of the play operator is expressed as:
where the relevant intermediate variable is defined as:
where r denotes the operator threshold, w represents the operator output, and ti refers to the partition instant within the interval [0, tE], where tN corresponds to tE.
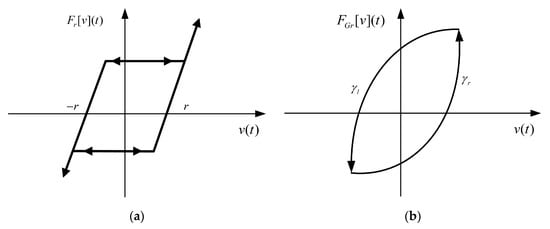
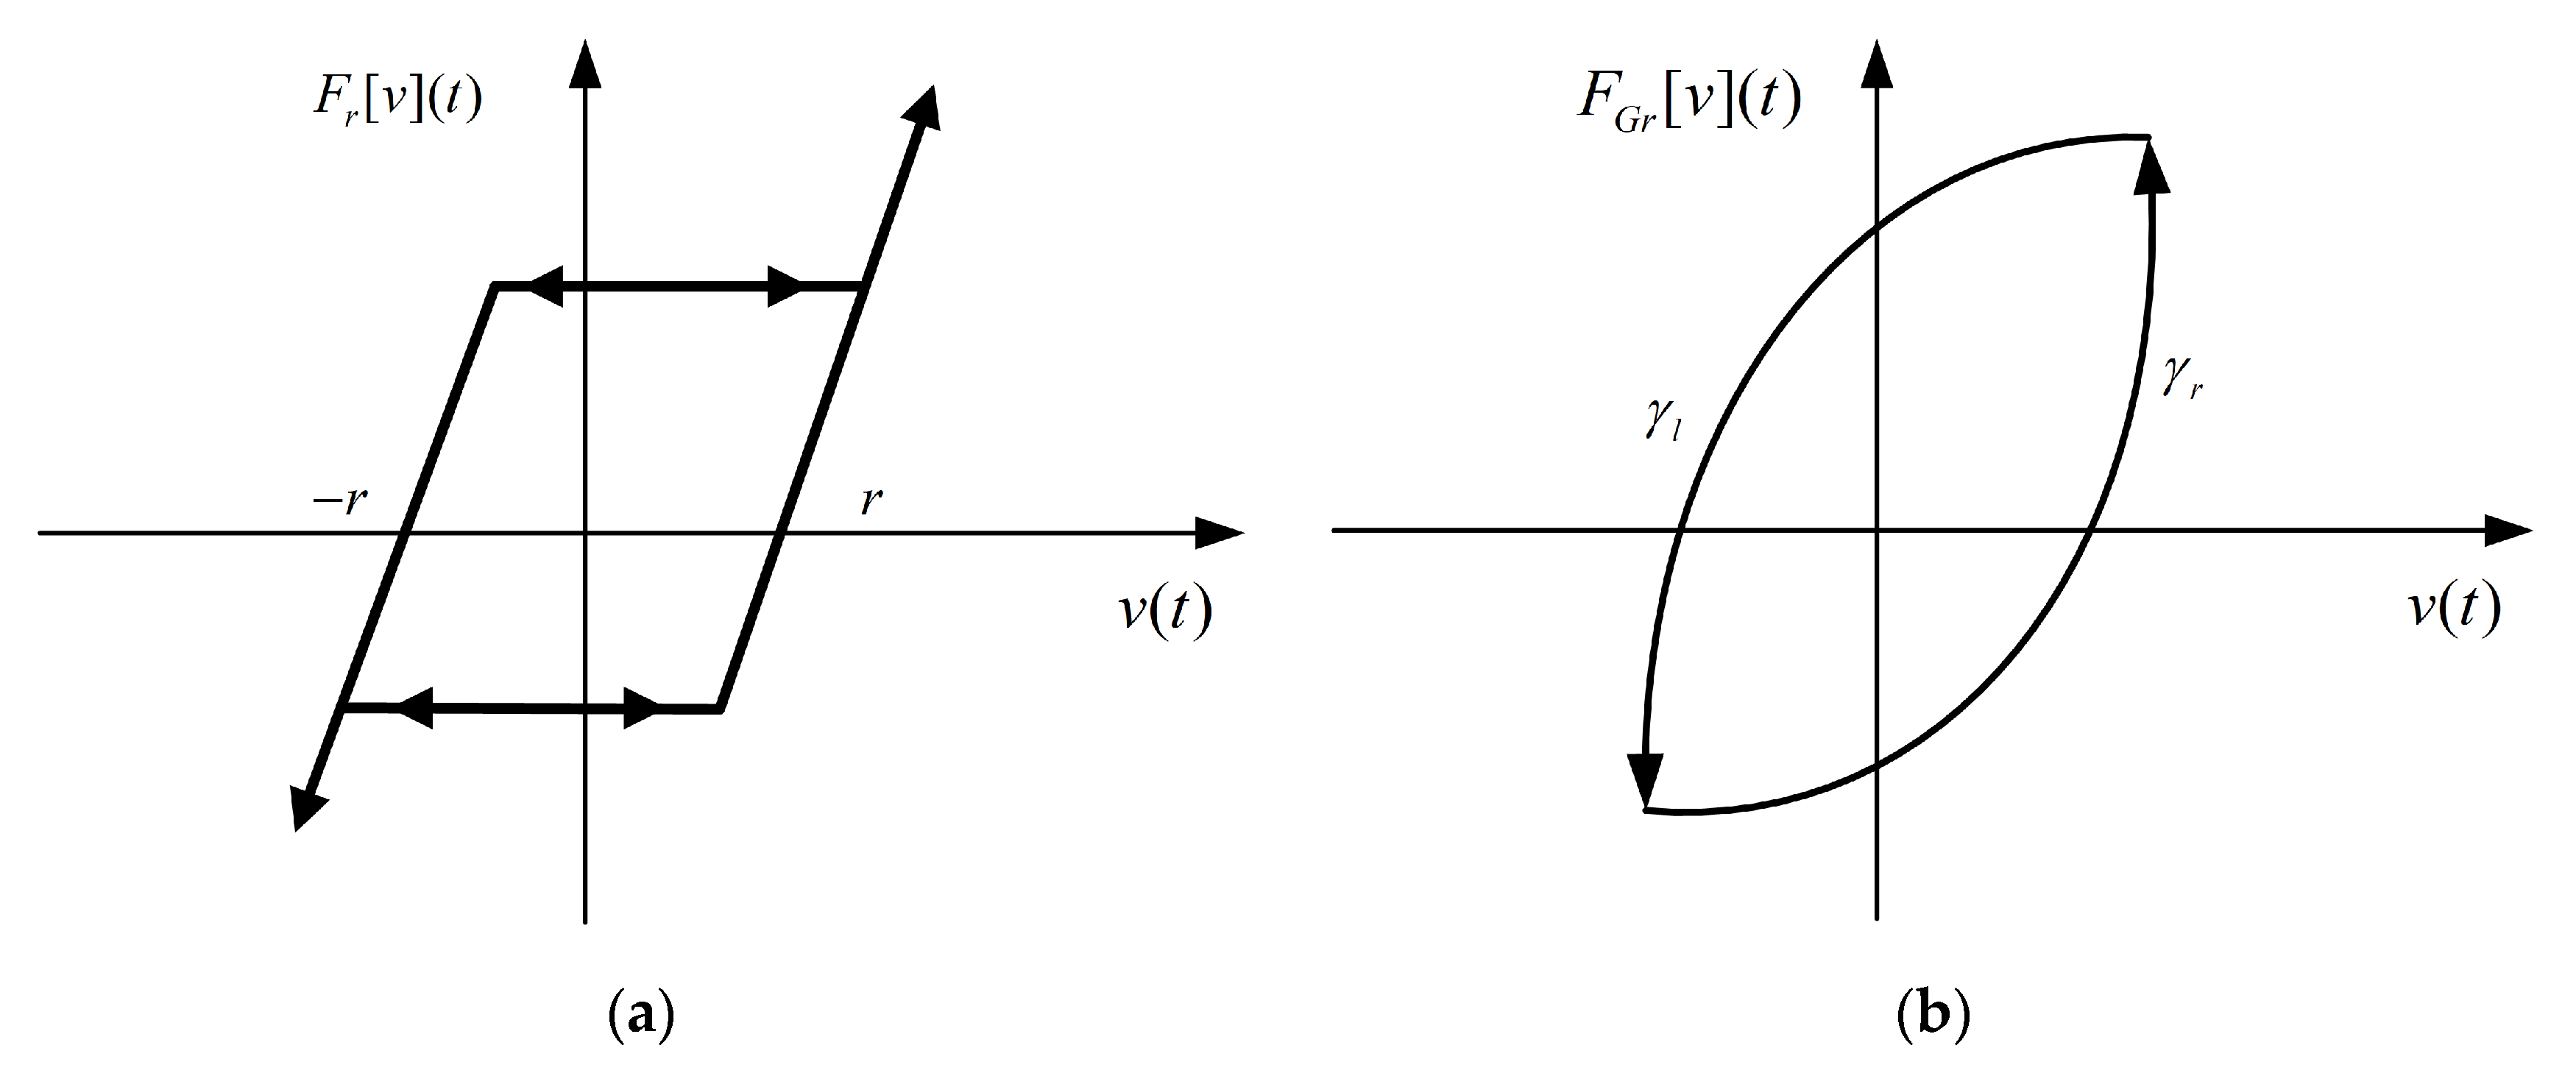
Based on the fundamental play operator illustrated in Figure 1a, the P-I model is established via a single integral operation. Its continuous-time representation, which serves as the basis for subsequent analysis, is given below:
where q is a positive constant, N is the total number of play operators, and p(ri) denotes the weighting coefficient of the play operator with threshold ri. The P-I model exhibits simple calculation procedures and low computational overhead due to its single-integral structure. Furthermore, it possesses a unique analytical inverse, which greatly simplifies the design of hysteresis compensation. These prominent advantages make the P-I model one of the most prevalent approaches for engineering-oriented hysteresis modeling.
Figure 1.
Characteristic curve of the play operator. (a) Classical play operator. (b) Generalized play operator.
2.2. Generalized P-I (GPI) Model
The classical P-I model suffers from insufficient accuracy in characterizing asymmetric hysteresis behaviors. To address this drawback, the GPI model is developed by introducing input-dependent envelope functions on the basis of the classical P-I structure, which effectively improves the model’s capability for asymmetric hysteresis characterization [23]. The generalized play operator adopted in the GPI model, as illustrated in Figure 1b, is presented as follows:
The envelope function can be adaptively selected according to practical hysteresis characteristics. For the inherent hysteresis of piezoelectric ceramics, a cubic polynomial function is generally utilized to construct the required envelope function:
On this basis, the output of the GPI model can be formulated as:
where c1 and c0 are constant coefficients; p(ri) denotes weighting coefficient of the play operator with threshold ri, which is defined as . The positive undetermined parameters ρ and τ can be efficiently identified using parameter-identification algorithms.
2.3. Enhanced Rate-Dependent GPI (ERGPI) Model
Although the GPI model achieves satisfactory performance in fitting static asymmetric hysteresis, it still produces considerable modeling errors for dynamic input signals with varying frequencies. Most existing rate-dependent improved models construct dynamic characteristics by introducing derivative terms of input signals. Inspired by the inherent amplitude attenuation and phase shift between the input and output responses of piezoelectric positioning stages under dynamic excitation, this study proposes an ERGPI model to accurately capture the rate-dependent hysteresis behaviors of piezoelectric actuators. In the proposed framework, the weighted superposition of the original input signal v(t) is taken as the updated input of the GPI model.
where xdl and xdr represent the dynamic input terms for the left and right envelope branches, respectively; Tl and Tr represent the memory lengths of the weighting functions hl(τ) and hr(τ), respectively. Different weight coefficients are assigned to the ascending and descending envelope branches to maintain the superior asymmetric fitting capability of the ERGPI model. The weight function hs(τ) is defined as:
where the positive constant ωcs and positive constant Ts are both undetermined parameters to be identified. Independent parameter groups are configured for the left and right envelope functions to realize differentiated weighting for forward and backward hysteresis branches. The frequency dependence of this weighting function stems from the fact that the time span of the weighting window is tied to the excitation period, rather than from explicit derivatives of the input signal.
Notably, the ERGPI model introduces only four extra identifiable parameters relative to the conventional GPI model, achieving a favorable trade-off between modeling accuracy and computational efficiency. The final output of the proposed ERGPI hysteresis model is expressed as:
3. Parameter Identification Based on ID-LSHADE
The L-SHADE algorithm is a high-performance adaptive differential evolution method and has been widely recognized as a baseline model for continuous black-box optimization [33]. It implements parameter self-adaptation via a success-history memory pool, in which the scaling factor F obeys a Cauchy distribution and the crossover probability CR follows a normal distribution. Compared with conventional DE, L-SHADE exhibits competitive overall performance in handling multimodal and nonlinear optimization problems, making it a reliable baseline for engineering parameter identification.
This study develops an ID-LSHADE algorithm embedded with multi-strategy adaptive selection and directional momentum mutation based on the canonical L-SHADE framework. The proposed algorithm retains the core superior mechanisms of conventional L-SHADE, including success-history-driven parameter self-adaptation, linear population size reduction (LPSR), external elite archiving, and p-best-guided elite mutation. Furthermore, three novel optimization mechanisms are integrated: individual evolutionary directional momentum mutation, multi-mutation adaptive competition, and fitness ranking-based scaling factor adaptation. These compound improvements enable a flexible and dynamic balance between global exploration and local exploitation.
3.1. Individual Evolutionary Directional Momentum Mutation
To fully exploit the effective evolutionary directions of historical iterations, an independent momentum term mi,g is maintained for each individual. The iterative update rule of the momentum term is formulated as:
where g denotes the generation index, i is the index of individuals in the population, ηi,g is the target vector of the i-th individual at generation g, ui,g is the trial vector generated for the i-th individual at generation g, mi,g represents the momentum term of the i-th individual at generation g, βm is the adaptive momentum coefficient, and p denotes the normalized progress of the parameter-identification process. The momentum mechanism enables high-quality individuals to evolve continuously along historically effective directions and accelerates convergence. Since the momentum term is only activated in the first local exploitation strategy, the random perturbation capability of global exploration strategies is well preserved without degradation.
3.2. Multi-Mutation Adaptive Competition Mechanism
Since the fixed current-to-pbest/1 mutation scheme in conventional L-SHADE lacks adaptability to varying evolutionary phases and individual fitness properties, three distinct mutation strategies and a corresponding strategy probability matrix are developed. The matrix, built from each scheme’s success rate and fitness improvement magnitude, supports online adaptive mutation-strategy selection during evolution.
The first mutation strategy is ranking-based directional momentum mutation, which integrates elite guidance, directional guidance from superior and inferior individuals, and directional momentum to achieve efficient and stable local exploitation. For the current target individual ηi,g, the mutation update formula for the donor vector di,g is expressed as:
where κi,g is the adaptive scaling factor, ηpbest,i,g is a solution vector randomly sampled from the top pbest% elite candidates of the current population at generation g, ηtop,i,g is randomly selected from high-ranking superior candidate sets, ηref,i,g is chosen from low-ranking inferior candidate sets with a 50% probability or selected from merged candidate sets otherwise, mi,g records the effective search directions of previous iterations, and cmom = Asin(πp) represents the iteration-adaptive momentum coefficient with a convex sinusoidal variation rule. The momentum weight reaches its maximum in the middle iteration stage to strengthen directional convergence and gradually decays in the late stage to suppress oscillation near the optimal neighborhood.
The second mutation strategy is designed for long-range global search without momentum memory. Two groups of differential vectors are employed to broaden the search range, and the mutation formula is given by:
where is a random individual different from ηi,g in the current population, and and are two distinct individuals selected from the merged set of the current population and external archive.
The third mutation strategy employs the global-best individual to perform intensive fine exploitation around the current optimal region. Its mutation formula is given by:
where ηbest,g denotes the fitness-optimal individual in the current generation, and and are randomly selected from the active population and differ from the target individual ηi,g.
To achieve adaptive competitive selection among the three mutation strategies, a strategy probability matrix Mstr is constructed. During evolution, each mutation strategy is randomly selected according to the probability distribution sampled from Mstr. After each iteration, all strategies that generate successful offspring and their corresponding fitness improvement weights ψi,g are collected to calculate the cumulative reward of each strategy:
where denotes the set of individuals that generate successful offspring using the j-th strategy, and 0.01 is a tiny smoothing constant that prevents zero probability and permanent abandonment of any single strategy. The new probability πj,g of the j-th subgroup at generation g is obtained by normalizing the cumulative rewards:
3.3. Fitness Ranking-Based Scaling Factor Adaptation
The conventional L-SHADE assigns a uniform baseline scale factor μκ,base to every individual in the same generation. To address this limitation, a ranking factor Ri,g is built according to the fitness rank of each individual for adaptive offset adjustment of the baseline scale factor μκ,i,g, which is given by
where κmin and κmax lower and upper bounds of the scale factor. High-ranking elite individuals are assigned larger μκ,i,g values to support wide-range fine neighborhood search, while low-ranking individuals adopt relatively smaller μκ,i,g values to avoid invalid violent perturbation.
4. Feedforward Control
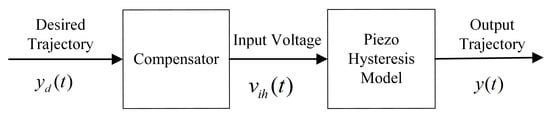
Feedforward control based on the inverse hysteresis model is the most straightforward and effective strategy to mitigate the inherent hysteresis nonlinearity of piezoelectric actuators. The overall configuration of the hysteresis feedforward compensation scheme is depicted in Figure 2. In ideal cases, the output trajectory y(t) can strictly track the desired trajectory yd(t) via the construction of an inverse hysteresis model.
Figure 2.
Feedforward compensation scheme.
In general, the inverse hysteresis model can be derived by solving the analytical inverse of the established hysteresis model. Nevertheless, analytical inversion generally involves complex mathematical derivation and heavy computational burden, making it impractical for real-world implementation. Memory-reduction techniques for rate-dependent Prandtl–Ishlinskii compensators have also been investigated to facilitate their implementation in high-precision motion systems [37]. To address this issue for practical engineering scenarios, the direct identification method of the inverse hysteresis model is employed to establish the feedforward compensator.
Motivated by the above practical compensation principle, this study adopts a data-driven modeling strategy to directly construct the direct inverse hysteresis model. Specifically, experimentally measured data of piezoelectric actuation responses are leveraged to identify the direct inverse model parameters, aiming to eliminate the hysteresis nonlinear effect of the actuator. The mathematical formulation of the established direct inverse hysteresis model is given as follows:
In the above equation, vih(t) is the compensated control voltage generated by the direct inverse hysteresis model for piezoelectric actuation. and are polynomial coefficients of the input term, and p′(ri) denotes the weight coefficient of the hysteresis operator. Correspondingly, ydl(t) and ydr(t), which are derived from the desired trajectory yd(t), are defined as:
The direct inverse model adopts the same ERGPI structure as the forward model, including the branch-weighting mechanism, with an identical parameter count.
5. Experimental Validation
Based on the experimental datasets acquired under different excitation conditions, this section first evaluates the rate-dependent hysteresis characteristics of the piezoelectric tip-tilt stage. The performance of the proposed ID-LSHADE parameter-identification algorithm is then assessed through comparisons with conventional L-SHADE and PSO. Subsequently, comparative modeling analyses among the GPI, the rate-dependent Prandtl-Ishlinskii (RDPI) [24], and the proposed ERGPI models are carried out under both single-frequency sinusoidal and multi-frequency composite excitations, where quantitative error indices are adopted to objectively evaluate and compare modeling accuracy. Finally, the identified ERGPI model is applied to construct a direct inverse feedforward compensator, and its effectiveness in suppressing hysteresis-induced positioning errors is experimentally validated through broadband trajectory tracking tests.
5.1. Experimental Setup
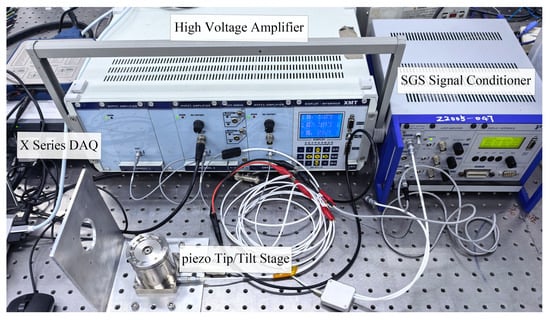
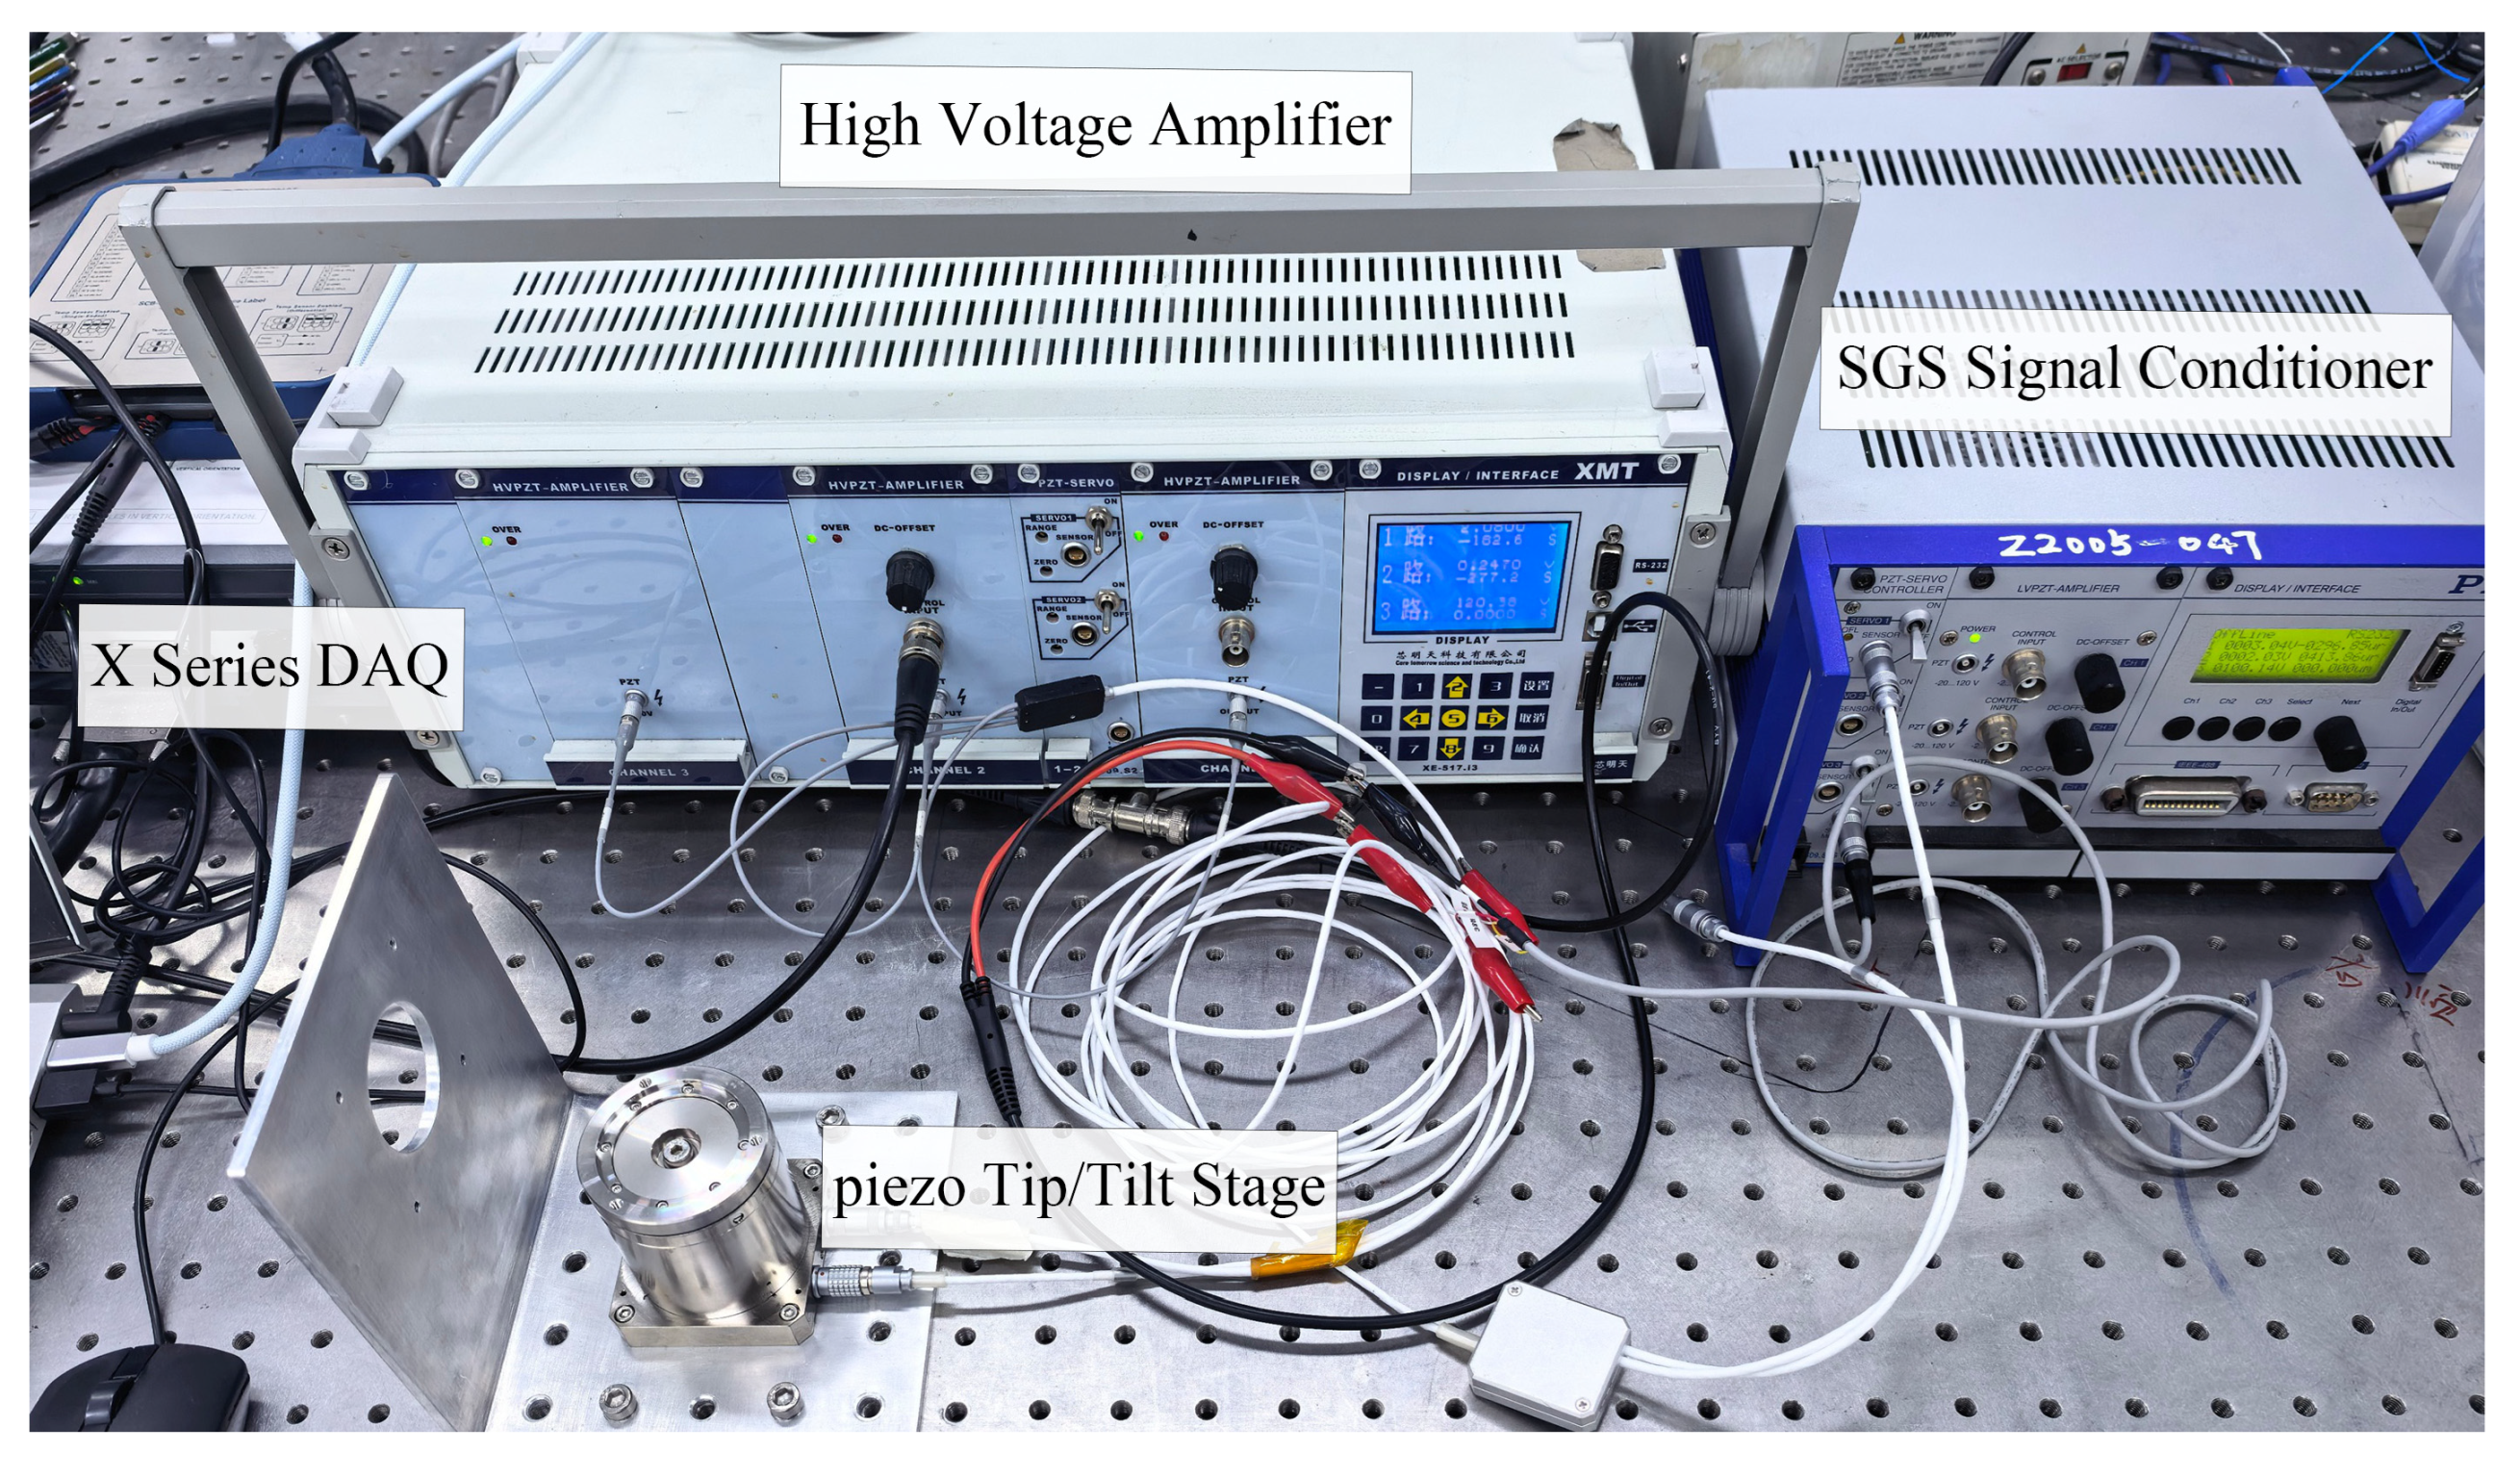
To verify the effectiveness of the developed ERGPI hysteresis model and the superiority of the ID-LSHADE parameter-identification algorithm under broadband excitation conditions, experimental validation is conducted on a self-built piezoelectric tip-tilt stage test system. This section first introduces the composition and working principle of the experimental hardware platform. Afterwards, the excitation signal configurations and test conditions for single-frequency sinusoidal and multi-frequency composite excitations are specified for subsequent model calibration and performance evaluation. Figure 3 presents the overall experimental system established in this work, which comprises a high-voltage amplifier, a piezoelectric tip-tilt stage, a strain gauge signal conditioner, and signal generation and acquisition modules. The piezoelectric tip-tilt stage adopted for testing is a customized S340K195 device produced by Physik Instrument (Physik Instrumente (PI), Karlsruhe, Germany), which integrates a built-in strain gauge sensor for real-time deflection angle measurement. The E-509.S3S signal processor (Physik Instrumente (PI), Karlsruhe, Germany) is utilized to convert the angular deflection output of the stage into a standard voltage signal, with an operational bandwidth of 3 kHz. The high-voltage amplifier (Model E05.00.2, Core-Tomorrow, Harbin, China) delivers a maximum driving current of 870 mA and achieves a bandwidth of 10 kHz. Signal excitation generation and experimental data acquisition are realized through a National Instruments PXIe-6358(National Instruments Corporation, Austin, TX, USA) acquisition board, which generates control signals for the piezoelectric stage and synchronously collects deflection angle responses. It should be noted that although the finite bandwidth of the E-509 signal conditioner makes a limited contribution to the measured system hysteresis, the inherent hysteresis of the piezoelectric actuator remains the dominant factor. Since the model is identified for the complete system chain, the conclusions on modeling and compensation remain applicable under the tested conditions.
Figure 3.
Hysteresis-testing experimental setup.
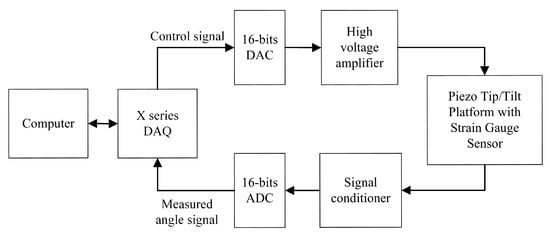
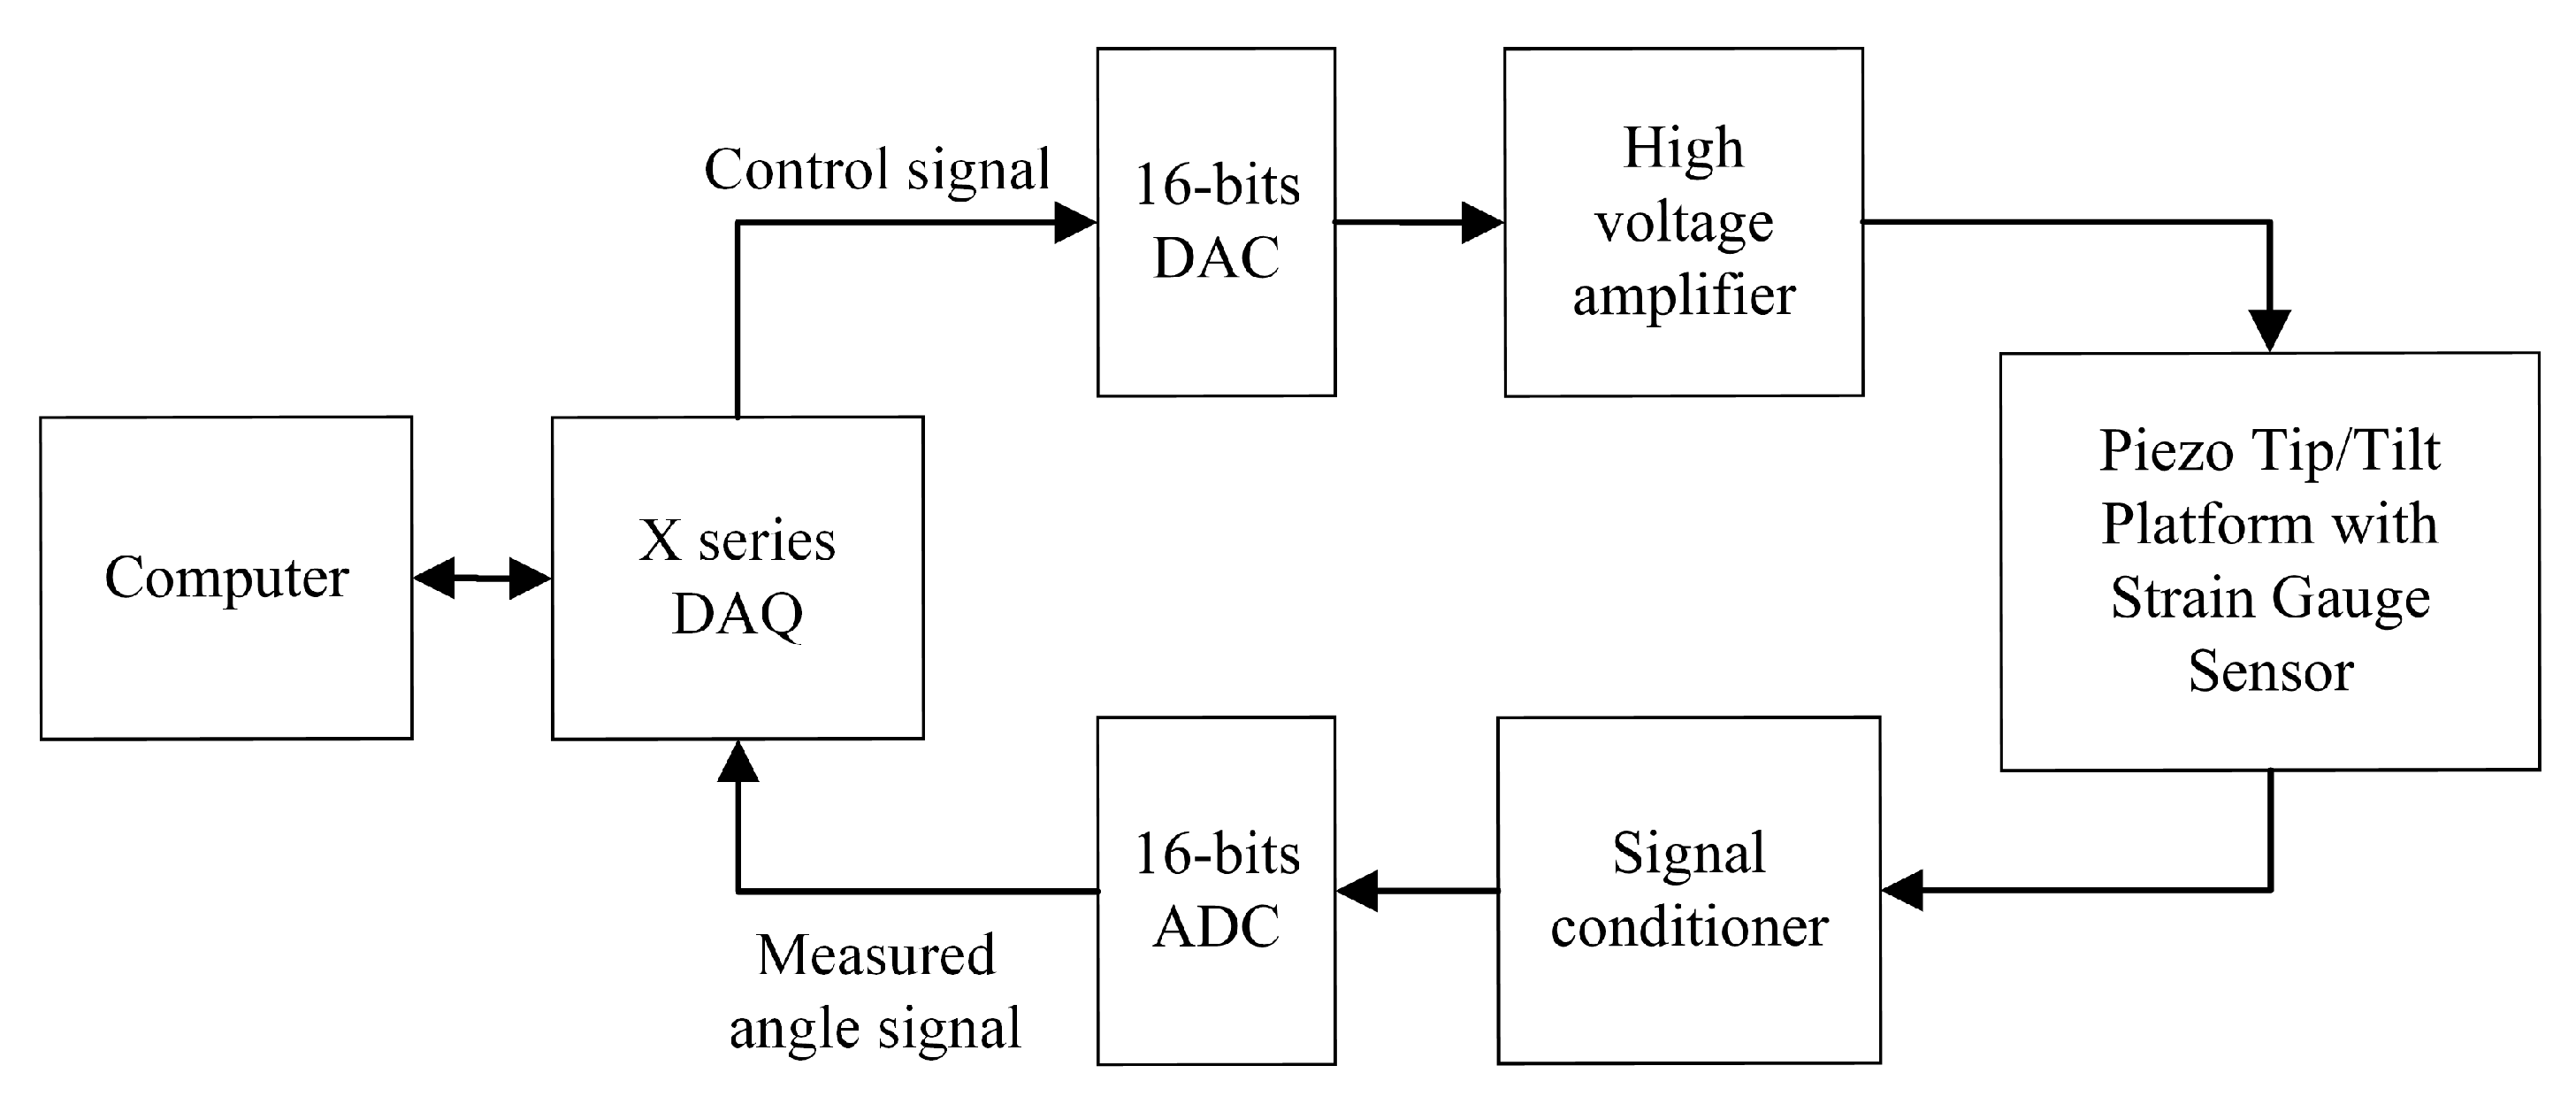
The operational principle and signal flow of the experimental platform are illustrated in Figure 4. Prior to each test, the frequency and amplitude of the excitation signal are configured. The preset digital control command is converted into an analog voltage signal through a 16-bit digital-to-analog converter (DAC). After being amplified by the high-voltage amplifier, the analog driving signal is exerted on the piezoelectric tip-tilt stage to trigger angular deflection. The mechanical displacement of the stage causes resistance variations in the embedded strain gauge sensor. Such subtle resistance fluctuations are conditioned and converted into standard voltage signals by the signal processor, which are further digitized via a 16-bit analog-to-digital converter (ADC) and finally transmitted back for data recording and post-processing. In all experiments, the sampling frequency is fixed at 100 kHz, yielding a sampling interval of 0.01 ms.
Figure 4.
Block diagram of the experimental setup.
To comprehensively validate the frequency-adaptive modeling accuracy of the proposed hysteresis model, two categories of excitation signals with distinct frequency characteristics are adopted. The first type is a single-frequency sinusoidal signal formulated as u(t) = Asin(2πft − π/2) + A, where the amplitude A is set to 36 V. Specifically, a low-frequency test is implemented at 4 Hz, and high-frequency swept tests are conducted from 30 Hz to 300 Hz with a uniform step of 30 Hz. The second type is a multi-frequency composite excitation signal expressed as u(t) = A(4 − sin(2πf1t + π/2) − sin(2πf2t + π/2) − sin(2πf3t + π/2) − sin(2πf4t + π/2)), which integrates four discrete frequency components, namely 3 Hz, 50 Hz, 100 Hz, and 300 Hz.
In addition to the excitation signals for hysteresis modeling, sinusoidal reference trajectories spanning 4 Hz to 300 Hz are adopted in the feedforward compensation experiments. These reference signals are employed as the desired output trajectories of the piezoelectric tip-tilt stage. For each test frequency, the reference trajectory is first fed into the identified inverse hysteresis model to generate the compensated driving voltage, which is then applied to the actuator through the experimental platform. The actual output trajectory is recorded and compared with the reference to quantitatively evaluate the tracking performance of the feedforward compensation scheme.
5.2. Rate-Dependent Hysteresis Characteristics of Piezoelectric Actuator
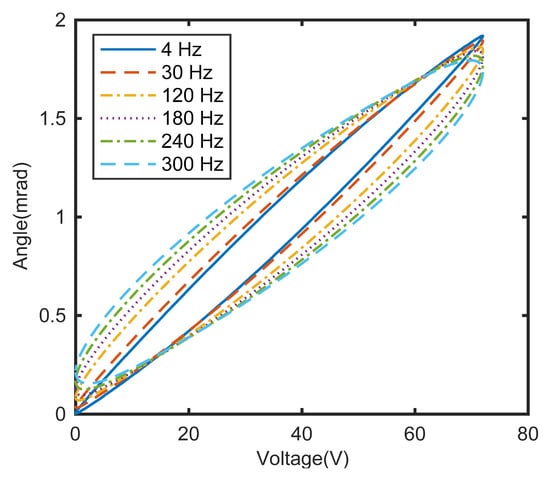
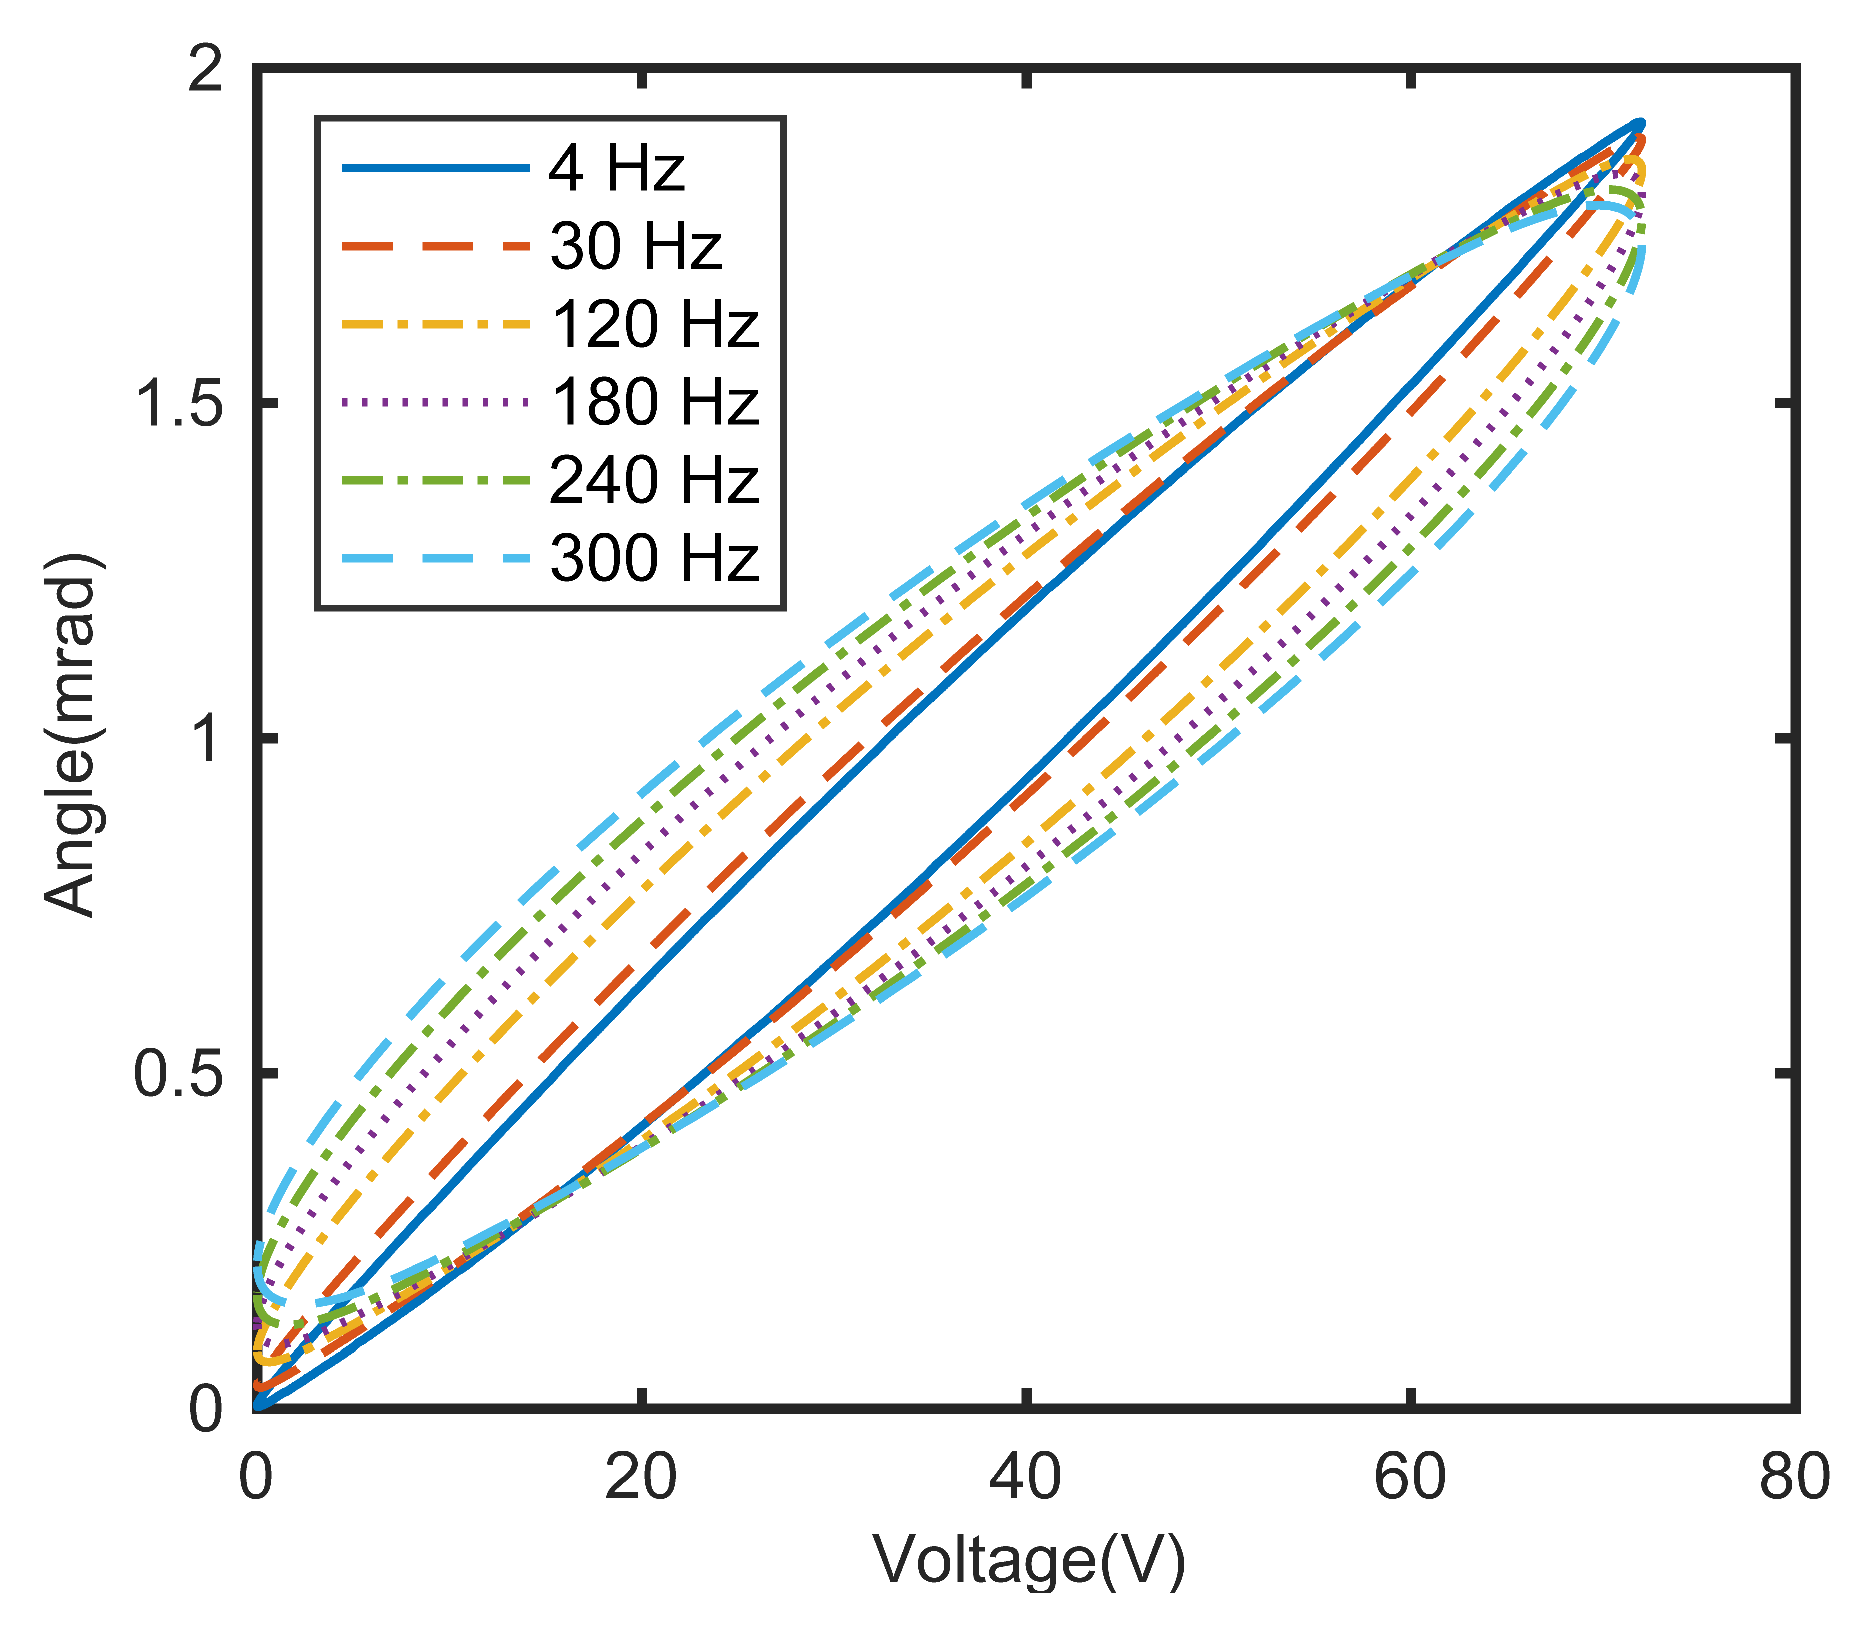
Before evaluating the performance of different hysteresis models, it is necessary to understand the inherent rate-dependent nonlinear behavior of the piezoelectric tip-tilt stage. In this subsection, the measured hysteresis loops at multiple representative excitation frequencies are analyzed to reveal the frequency-related evolution rules of loop width, output amplitude and phase lag. The hysteresis characteristics of the piezoelectric tip-tilt stage under excitation signals with different frequencies are illustrated in Figure 5. Typical hysteresis curves at excitation frequencies of 4 Hz, 30 Hz, 120 Hz, 180 Hz, 240 Hz, and 300 Hz are selected for analysis. Obvious hysteresis phenomena can be observed, and the hysteresis loop exhibits distinct frequency-dependent characteristics. As the excitation frequency increases, the width of the hysteresis loop gradually expands. Specifically, the loop width is 0.26 mrad at 4 Hz, increases to 0.43 mrad at 120 Hz, and further rises to 0.58 mrad at 300 Hz. Meanwhile, the output amplitude decreases with increasing frequency. In addition, a significant phase offset exists between the input excitation and output angular response. The peak output angle obviously lags behind the peak input signal, indicating asynchronous extremum arrival between the input and output.
Figure 5.
Hysteresis curves of output angle versus input voltage at different excitation frequencies.
5.3. Parameter Identification of the Hysteresis Model
Given the measured hysteresis datasets at all excitation frequencies, parameter identification is performed in a single run using the broadband multi-frequency dataset to determine all unknown coefficients of the ERGPI hysteresis model. The total number of identifiable ERGPI model parameters is 12. This subsection compares the optimization behaviors of PSO, conventional L-SHADE and the proposed ID-LSHADE algorithm. Convergence curves and final fitness values are analyzed to verify the optimization efficiency of ID-LSHADE and obtain well-optimized model parameters for subsequent hysteresis fitting and validation. The fitness function utilized for optimization is defined as:
where ymi and yei represent the model-predicted output and the experimentally measured output, respectively. The identification accuracy is closely related to the initial population size and the maximum iteration number. Through comprehensive trial tests, the initial population size is set to 300 and the maximum iteration number is set to 1000. To eliminate random interference, each identification case is repeated 5 times, and the optimal result is selected for subsequent analysis.
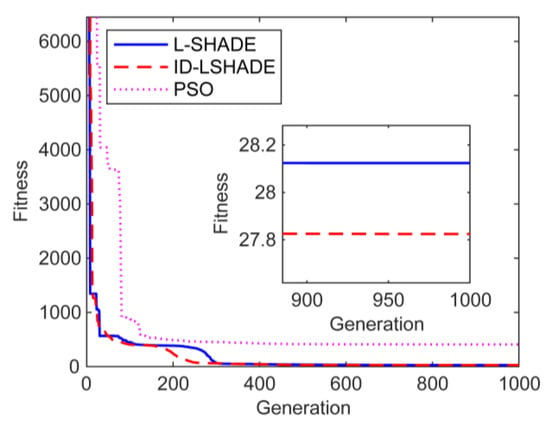
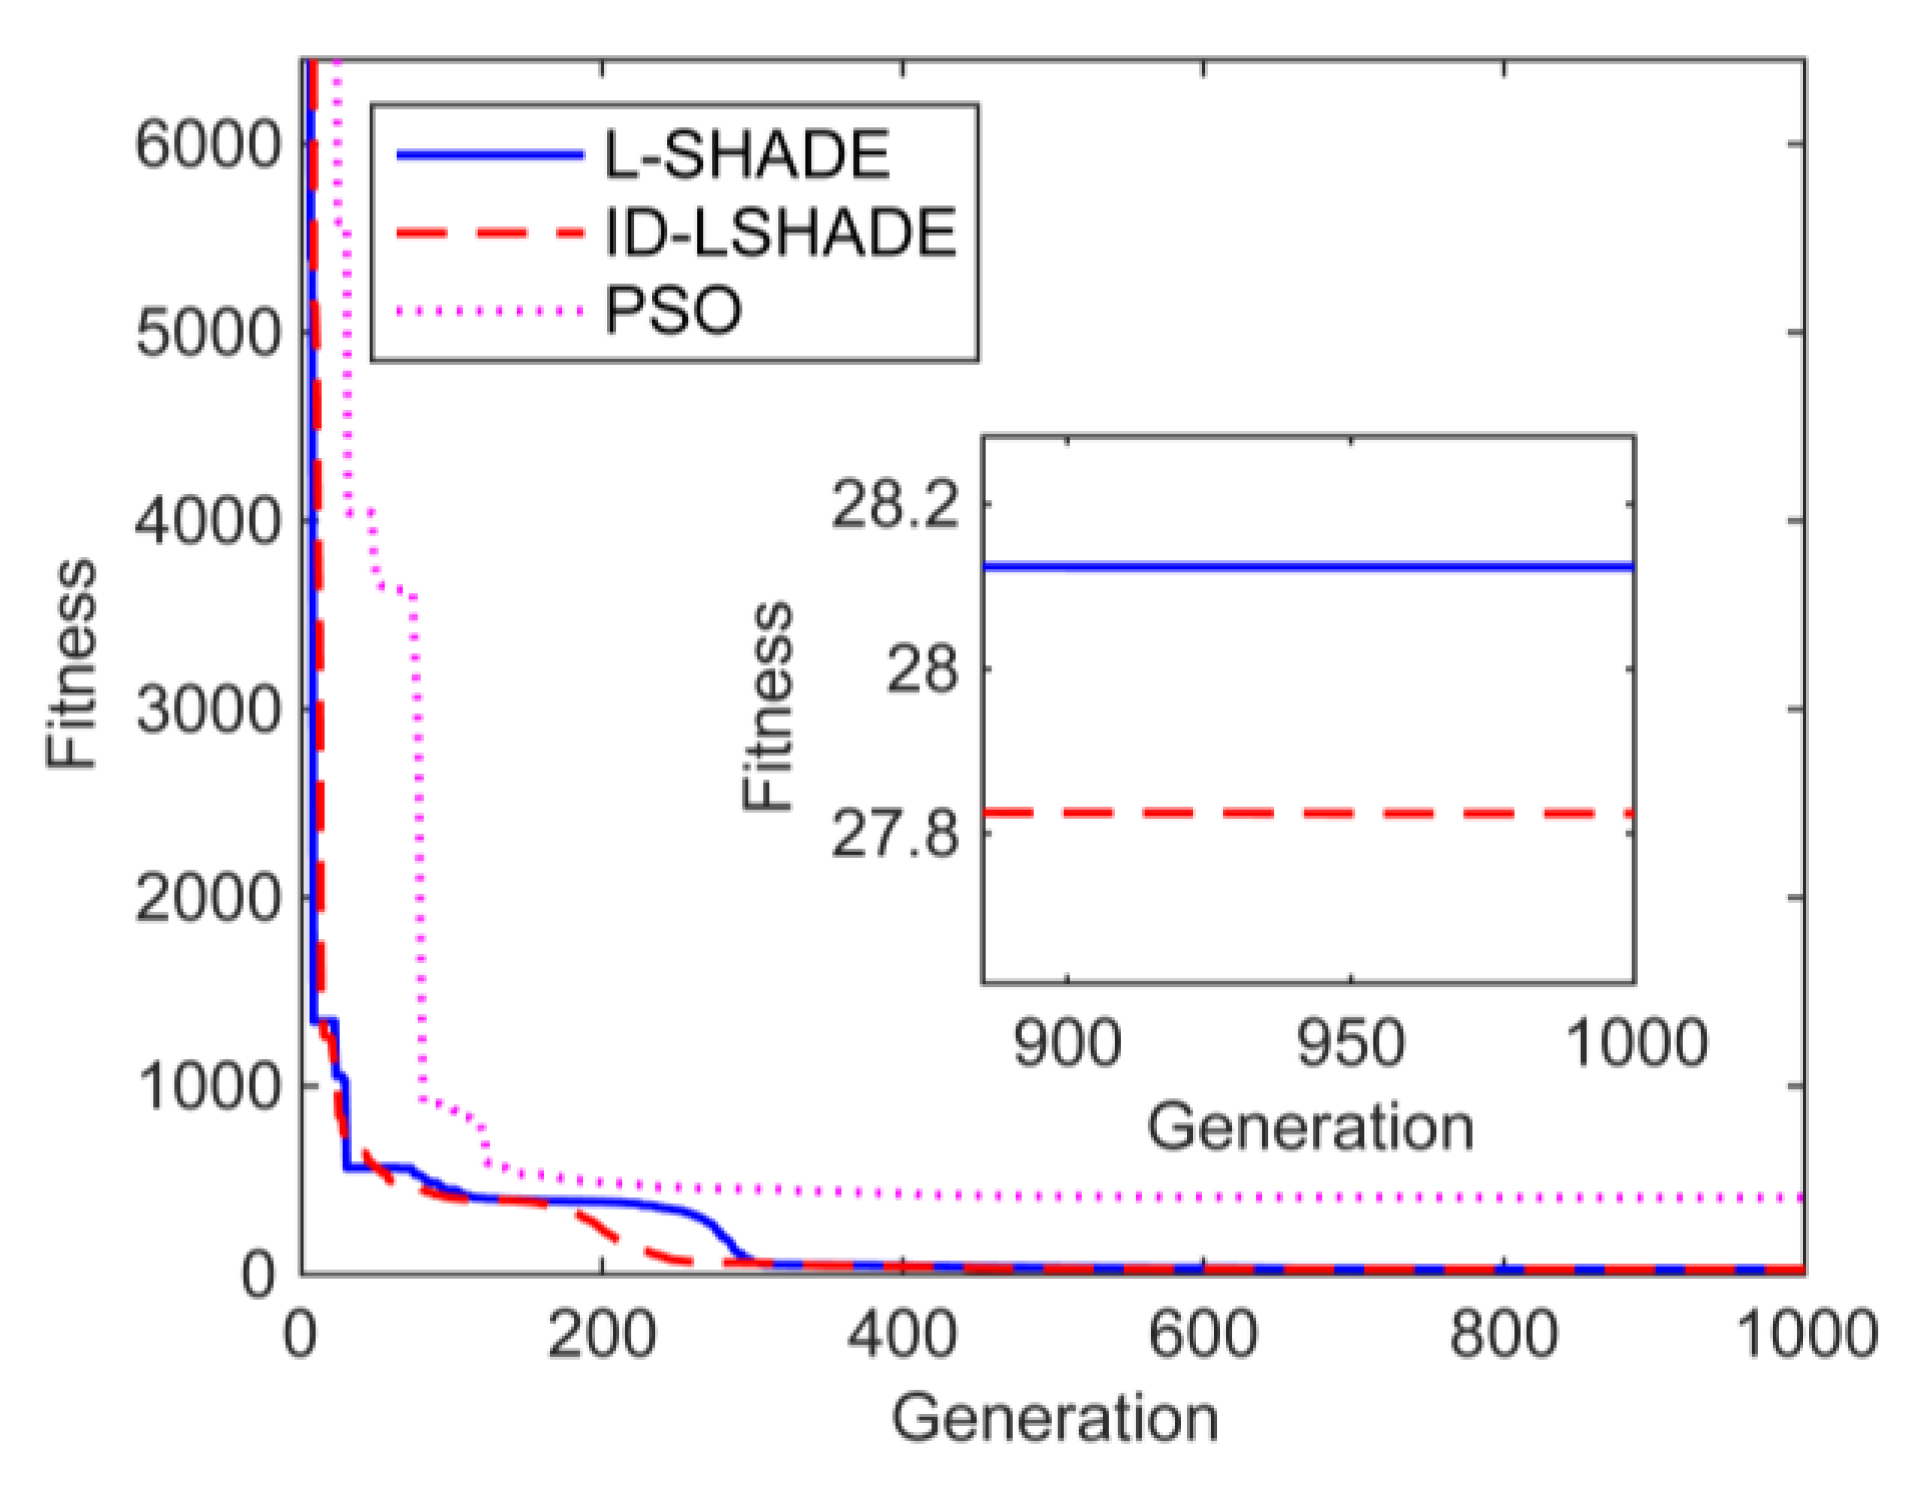
To verify the performance of the proposed ID-LSHADE algorithm, conventional L-SHADE and particle swarm optimization (PSO) are employed for comparative parametric identification of the ERGPI model. The convergence trajectories of the three algorithms are displayed in Figure 6. The comparison results reveal that ID-LSHADE yields substantially faster convergence and lower fitness values within early-to-middle iterations. For instance, at the 200th generation, the fitness values of PSO, L-SHADE, and ID-LSHADE are 488.9, 386.9, and 239.7, respectively. Regarding the final optimized fitness, PSO converges to 408.41, L-SHADE reaches 28.12, and ID-LSHADE obtains a marginally improved value of 27.82. These results verify the competitive overall optimization capability of ID-LSHADE, especially its improved convergence efficiency.
Figure 6.
Evolution of fitness values for L-SHADE, ID-LSHADE and PSO.
5.4. Experimental Validation of the Proposed Model
Based on the optimized parameters derived from the preceding parameter-identification process, the modeling performance of different hysteresis models can be further assessed. In this subsection, the conventional GPI, RDPI, and the proposed ERGPI models, all identified via the ID-LSHADE algorithm, are compared under multiple single-frequency sinusoidal excitations. Numerical simulations are conducted for model validation, where the classical GPI model and the RDPI model are selected as benchmarks for comparative analysis. Visual fitting curves together with quantitative error metrics are adopted to comprehensively evaluate the broadband modeling capability of each model.
The fitting results across different excitation frequencies are illustrated in Figure 7. As depicted in Figure 7a–f, the hysteresis-loop fitting performance varies distinctly among the three models across excitation frequencies ranging from 4 Hz to 300 Hz. The conventional GPI model shows obvious deviation from the measured hysteresis trajectory at all frequencies. Its predicted loop gradually drifts away from experimental data as frequency rises, producing considerable mismatch, especially in the upper and lower turning regions of the hysteresis loop. Compared with GPI, the RDPI model achieves evident improvement in trajectory tracking; nevertheless, noticeable discrepancies still exist, and fitting errors become more prominent under high-frequency excitations such as 240 Hz and 300 Hz. By contrast, the ERGPI model closely overlaps the experimentally measured hysteresis curves throughout the entire tested frequency range. Even at 300 Hz, the predicted hysteresis loop maintains high consistency with experimental observations without obvious deterioration.
Figure 7.
Fitting agreement of hysteresis curves and corresponding errors for sinusoidal inputs: (a) 4 Hz, (b) 30 Hz, (c) 120 Hz, (d) 180 Hz, (e) 240 Hz, (f) 300 Hz.
The embedded sub-plots in each sub-figure present the corresponding time-domain error distributions. The error amplitude of the GPI model remains at a relatively high level for all test frequencies. Although the RDPI model reduces error fluctuation to some extent, residual errors are still non-negligible, particularly under high-frequency conditions. The ERGPI model yields the smallest error magnitude and narrowest fluctuation band in all cases. Its time-domain error stays within a low amplitude range, demonstrating stable prediction performance for both low- and high-rate hysteresis responses.
Three quantitative evaluation indices, including root mean square error (RMSE), maximum absolute error (MAX), and mean absolute error (MAE), are adopted to comprehensively assess the model performance. The corresponding definitions are given as follows:
To quantitatively evaluate the hysteresis modeling performance of different models under broadband excitation conditions, normalized relative error indicators are adopted to achieve objective and fair comparison across various operating frequencies. Each relative error index is calculated as the ratio of the absolute modeling error to the peak-to-peak value of the measured angular displacement, which effectively eliminates evaluation deviations caused by amplitude differences under different working conditions. The quantitative error statistics of the GPI, RDPI, and ERGPI models at six typical frequencies ranging from 4 Hz to 300 Hz are summarized in Table 1. The statistical results reveal distinct performance discrepancies among the three models. The conventional GPI model presents the largest modeling error, with its relative RMSE fluctuating from 1.67% to 6.20% within the tested frequency band. The RDPI model achieves evident accuracy improvement over the GPI model, with the relative RMSE controlled between 0.72% and 3.03%. In comparison, the proposed ERGPI model delivers stable and higher modeling accuracy across all test cases, maintaining a low relative RMSE of only 0.37% to 1.04% over the full broadband range. Unlike the pronounced accuracy degradation of conventional models at high frequencies, the ERGPI model sustains low error levels even under complex high-frequency hysteresis conditions. These quantitative results confirm that the ERGPI model can accurately characterize the frequency-dependent hysteresis nonlinearity of piezoelectric actuators, enabling reliable high-precision modeling for broadband dynamic excitation scenarios.
Table 1.
Comparison of root mean square error (RMSE), maximum absolute error (MAX), and mean absolute error (MAE) across different models under various excitation frequencies. Values in parentheses denote relative errors (in %).
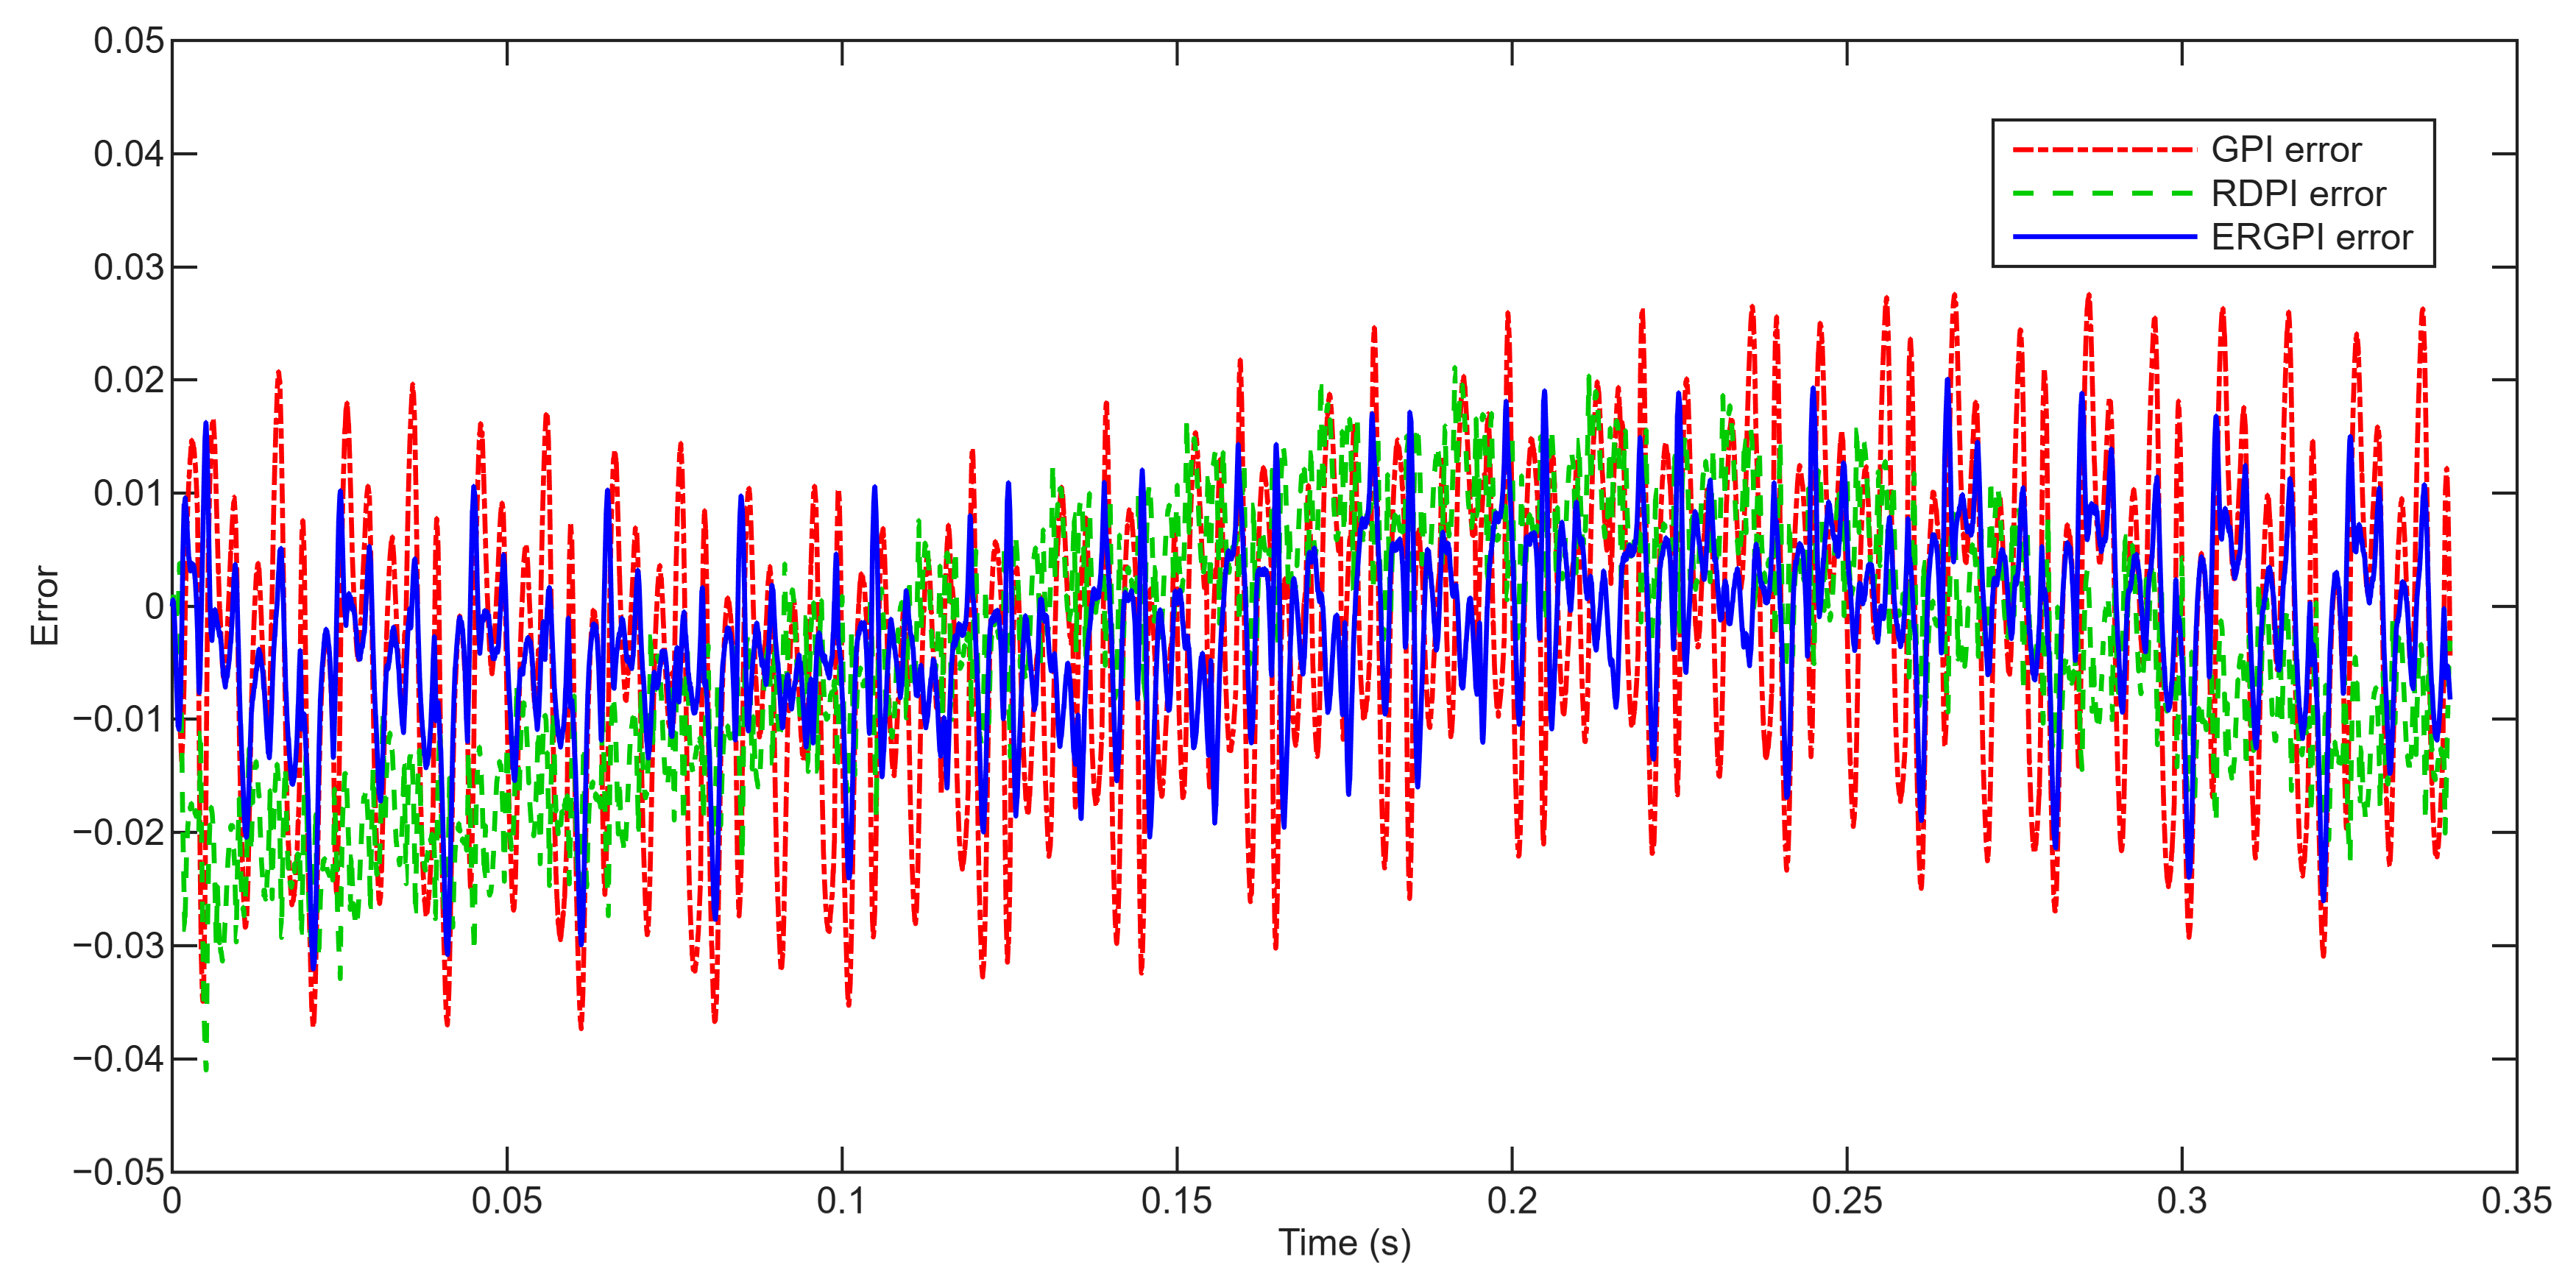
To further comprehensively verify the hysteresis-characterizing capability of the proposed ERGPI model, experiments were conducted on a piezoelectric tip–tilt stage under multi-frequency composite excitation, followed by model parameter identification and accuracy validation. Under identical experimental conditions and identification criteria, the classical GPI and RDPI models were selected for horizontal comparison to evaluate the performance of the proposed ERGPI model. The fitting curves between the predicted outputs of the ERGPI, GPI, and RDPI models and the experimental measurements, along with their corresponding error distributions, are shown in Figure 8. Quantitative analysis of the experimental results yields the following error metrics. The root-mean-square error (RMSE), maximum absolute error (MAX), and mean absolute error (MAE) of the GPI model are 0.014 mrad (0.81%), 0.037 mrad (2.13%), and 0.011 mrad (0.63%), respectively; the corresponding three error indices for the RDPI model are 0.012 mrad (0.69%), 0.041 mrad (2.36%), and 0.010 mrad (0.58%); and those for the proposed ERGPI model are 0.008 mrad (0.46%), 0.032 mrad (1.84%), and 0.006 mrad (0.35%), respectively. Quantitative comparison reveals that the ERGPI model consistently yields lower error indices, exhibits higher agreement between the predicted and measured trajectories, and demonstrates a narrower error fluctuation range than the GPI and RDPI models. These results indicate that the ERGPI model is capable of accurately characterizing the hysteresis nonlinearity of the piezoelectric tip–tilt stage under multi-frequency composite excitation and effectively adapting to system responses under complex-frequency excitation conditions. Overall, the findings further substantiate the adaptability, modeling accuracy, and practical efficacy of the proposed ERGPI model.
Figure 8.
Errors of the GPI, RDPI and ERGPI models under composite-frequency excitation.
5.5. Experimental Verification of Feedforward Control
The above sections have elaborated the theoretical principle and modeling approach of the hysteresis compensation strategy. On this basis, experimental verification is performed to evaluate the practical effectiveness and broadband performance of the designed feedforward control scheme. The specific experimental implementation and tracking performance analysis are presented as follows. For the parameter identification of the inverse hysteresis model, the experimentally measured angular displacement y(t) is defined as the model input, and the corresponding measured driving voltage v(t) is set as the model output. Based on the constructed experimental dataset, the proposed ID-LSHADE algorithm is adopted to identify the undetermined parameters of the inverse hysteresis model, yielding optimal model coefficients for feedforward compensation. During the actual compensation process, the reference trajectory yd(t) is imported into the well-identified inverse model to generate the compensated driving voltage vih(t), which is subsequently applied to the piezoelectric actuator for high-precision trajectory tracking.
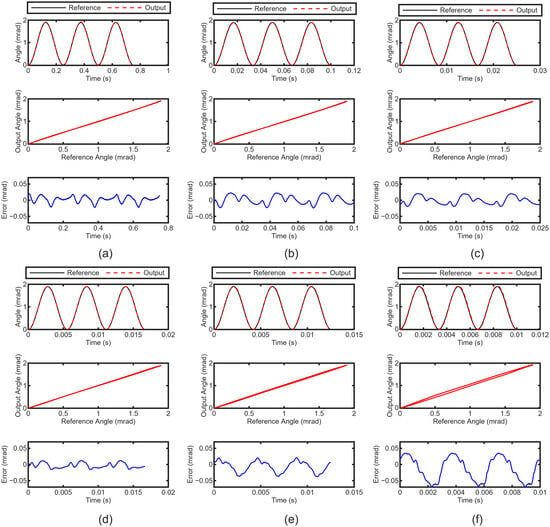
To fully verify the broadband compensation performance of the proposed feedforward strategy, sinusoidal reference signals spanning a broad frequency range of 4 Hz to 300 Hz are adopted for experimental tests. Figure 9a–f comparatively present the trajectory tracking results, hysteresis characteristics between reference and actual trajectories, and corresponding tracking errors of the piezoelectric system after feedforward compensation at typical frequencies of 4 Hz, 30 Hz, 120 Hz, 180 Hz, 240 Hz, and 300 Hz. At the low frequency of 4 Hz, the actual output trajectory matches the reference trajectory well, and the inherent hysteresis loop is substantially suppressed. Although the tracking error exhibits a slight upward trend with the increase in excitation frequency, the system can still achieve reliable tracking performance within the entire tested frequency band. The qualitative experimental results demonstrate that the proposed feedforward compensation method can effectively suppress hysteresis nonlinearity and realize high-precision trajectory tracking for piezoelectric actuators under broadband working conditions.
Figure 9.
Trajectory tracking results with feedforward compensation under sinusoidal references at (a) 4 Hz, (b) 30 Hz, (c) 120 Hz, (d) 180 Hz, (e) 240 Hz, (f) 300 Hz. Each subfigure presents the time-domain tracking response, the reference–output hysteresis characteristics, and the tracking error.
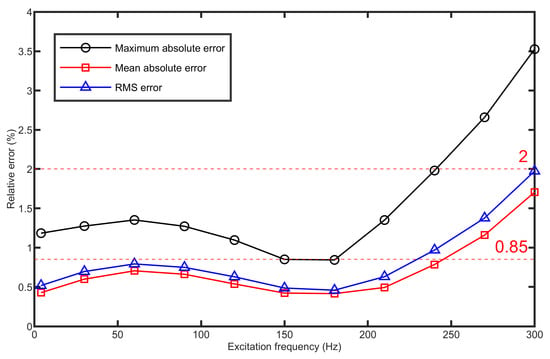
For quantitative performance evaluation, Figure 10 summarizes the relative root-mean-square (RMS) tracking errors of the piezoelectric deflection system within the 4–300 Hz excitation range, together with the maximum and average absolute tracking errors as auxiliary evaluation indices. The quantitative results show that the relative RMS tracking error is maintained within 0.85% in the frequency range of 4–210 Hz, with the minimum error of 0.46% achieved at 180 Hz. For frequencies above 210 Hz, the tracking error increases slightly. Nevertheless, the relative RMS error is still controlled within 2% at the maximum test frequency of 300 Hz, which retains satisfactory tracking accuracy. This reveals that the developed feedforward compensation scheme can effectively mitigate the hysteresis nonlinearity of piezoelectric ceramics and deliver stable, high-precision trajectory tracking capability under broadband sinusoidal excitation.
Figure 10.
Relative tracking errors (RMS, maximum absolute, and mean absolute) of the compensated system versus excitation frequency from 4 Hz to 300 Hz.
As a comprehensive evaluation index for overall tracking deviation, the RMS error fluctuates slightly in the low and medium frequency bands, verifying the excellent steady-state performance and stable tracking capability of the compensated system. The overall experimental results sufficiently confirm that the proposed feedforward strategy can maintain low-level RMS tracking errors and possesses outstanding broadband steady-state tracking performance for piezoelectric precision positioning systems.
6. Conclusions
This study addresses the low modeling accuracy caused by the rate-dependent hysteresis nonlinearity of piezoelectric tip-tilt stages under broadband excitation. An enhanced rate-dependent generalized Prandtl–Ishlinskii (ERGPI) model and an improved dynamic adaptive differential evolution (ID-LSHADE) algorithm are proposed for hysteresis modeling and parameter identification. By applying independent weighting to the ascending and descending branches of the envelope function, the ERGPI model characterizes the frequency evolution of hysteresis loops with only four additional parameters, while avoiding the numerical instability introduced by the input-differential terms of traditional rate-dependent P-I models. The ID-LSHADE algorithm integrates multi-mutation adaptive competition, individual evolutionary directional momentum mutation, and ranking-based dynamic parameter adaptation, effectively balancing global exploration and local exploitation and thereby improving both the convergence efficiency and the stability of parameter optimization. Experiments conducted on a custom-built piezoelectric test platform under single-frequency sinusoidal excitation from 4 Hz to 300 Hz demonstrate that ID-LSHADE accelerates the convergence process while achieving competitive final identification accuracy. The ERGPI model attains high-precision fitting of dynamic hysteresis loops across the entire tested frequency band with stable prediction performance. Furthermore, a direct inverse feedforward compensator constructed from the identified ERGPI model reduces the relative RMS tracking error to within 0.85% over 4–210 Hz and below 2% at 300 Hz, verifying its effectiveness in suppressing rate-dependent hysteresis. Future work will focus on integrating the proposed model with feedback control strategies to further enhance robustness against disturbances and model mismatch in practical piezoelectric micropositioning systems.
Author Contributions
Conceptualization, P.W. and K.S.; methodology, P.W.; software, S.D.; validation, P.W. and Z.H.; formal analysis, P.W.; investigation, P.W.; resources, B.C. and K.S.; data curation, P.W.; writing—original draft preparation, P.W.; writing—review and editing, B.C., K.S. and X.W.; visualization, Z.H.; supervision, B.C.; project administration, B.C. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The data presented in this study are available on request from the corresponding author. The raw experimental data are not publicly available due to ongoing related research activities within the research group.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Ahmad, I. Enhanced Prandtl–Ishlinskii Hysteresis Modeling With Two Degree-of-Freedom H∞ Integral Control Design for a Piezoactuated Micropositioning System. IEEE Access 2025, 13, 180992–181004. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; Hou, B.; Hu, C.; Zhu, Y. Time-Frequency Analysis-Based Real-Time Iterative Compensation for Piezoelectric Nanopositioning Stage. IEEE/ASME Trans. Mechatron. 2024, 29, 4468–4479. [Google Scholar] [CrossRef] [Scilit]
- Chen, B.; Li, H.; Song, K.-F.; Guo, Q.-F.; Zhang, P.-J.; He, L.-P.; Dai, S.; Wang, X.-D.; Wang, H.-F.; Liu, C.-L.; et al. The Lyman-alpha Solar Telescope (LST) for the ASO-S mission–II. design of LST. Res. Astron. Astrophys. 2019, 19, 159. [Google Scholar] [CrossRef] [Scilit]
- Baziyad, A.G.; Ahmad, I.; Salamah, Y.B. Precision Motion Control of a Piezoelectric Actuator via a Modified Preisach Hysteresis Model and Two-Degree-of-Freedom H-Infinity Robust Control. Micromachines 2023, 14, 1208. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Jiles, D.C.; Atherton, D.L. Theory of the magnetisation process in ferromagnets and its application to the magnetomechanical effect. J. Phys. D Appl. Phys. 1984, 17, 1265–1281. [Google Scholar] [CrossRef] [Scilit]
- Liu, V.-T.; Wing, H.-Y. Classical Preisach Model Based on Polynomial Approximation and Applied to Micro-Piezoelectric Actuators. Symmetry 2022, 14, 1008. [Google Scholar] [CrossRef] [Scilit]
- Moree, G.; Leijon, M. Review of Play and Preisach Models for Hysteresis in Magnetic Materials. Materials 2023, 16, 2422. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Cheng, L.Q.; Chen, W.Z.; Tian, L.G.; Xie, Y. A feedforward-feedback controller based on modified Prandtl-Ishlinskii model and submodel for tracking control the trajectories of piezoelectric actuator. Microsyst. Technol. 2024, 30, 1007–1024. [Google Scholar] [CrossRef] [Scilit]
- Cheng, L.; Chen, W.; Tian, L. A modified direct inverse Prandtl–Ishlinskii model based on two sets of operators for the piezoelectric actuator hysteresis compensation. Int. J. Appl. Electromagn. Mech. 2022, 68, 177–191. [Google Scholar] [CrossRef] [Scilit]
- Xu, R.; Tian, D.P.; Zhou, M.L. A rate-dependent KP modeling and direct compensation control technique for hysteresis in piezo-nanopositioning stages. J. Intell. Mater. Syst. Struct. 2022, 33, 629–640. [Google Scholar] [CrossRef] [Scilit]
- Yuan, Z.; Li, X.; Chen, X.; Wu, J. A Novel Rate-Dependent Hysteresis Framework for Piezoelectric Actuators: Modeling, Identification, and Control. IEEE Trans. Ind. Electron. 2026, 73, 1152–1163. [Google Scholar] [CrossRef] [Scilit]
- Lu, J.; Wang, J.; Bo, Y.; Zhang, X. Hysteresis Modeling and Compensation for a Fast Piezo-Driven Scanner in the UAV Image Stabilization System. Drones 2023, 7, 392. [Google Scholar] [CrossRef] [Scilit]
- Flores, G.; Rakotondrabe, M. Dahl Hysteresis Modeling and Position Control of Piezoelectric Digital Manipulator. IEEE Control Syst. Lett. 2023, 7, 1021–1026. [Google Scholar] [CrossRef] [Scilit]
- Yang, L.; Zhong, R.; Li, D.; Li, Z. A fractional-order Duhem model of rate-dependent hysteresis for piezoelectric actuators. Meas. Control 2022, 55, 974–982. [Google Scholar] [CrossRef] [Scilit]
- Zhou, M.; Yang, X.; Zhang, C.; Pan, W.; Yu, Y.; Song, M.; He, Y.; Gao, W. Duhem model and inverse compensation controller for trajectory tracking in piezo-actuated micropositioning stage based on neural network. Sens. Actuator A-Phys. 2024, 377, 10. [Google Scholar] [CrossRef] [Scilit]
- Bi, S.; Wang, L.; Zhao, Y.; Deng, M. Operator-based robust control for nonlinear uncertain systems with unknown backlash-like hysteresis. Int. J. Control Autom. Syst. 2016, 14, 469–477. [Google Scholar] [CrossRef] [Scilit]
- Gu, G.-Y.; Zhu, L.-M.; Su, C.-Y. Modeling and Compensation of Asymmetric Hysteresis Nonlinearity for Piezoceramic Actuators With a Modified Prandtl–Ishlinskii Model. IEEE Trans. Ind. Electron. 2014, 61, 1583–1595. [Google Scholar] [CrossRef] [Scilit]
- Yang, M.-J.; Li, C.-X.; Gu, G.-Y.; Zhu, L.-M. Modeling and compensating the dynamic hysteresis of piezoelectric actuators via a modified rate-dependent Prandtl–Ishlinskii model. Smart Mater. Struct. 2015, 24, 125006. [Google Scholar] [CrossRef] [Scilit]
- Gan, J.; Zhang, X.; Wu, H. A generalized Prandtl-Ishlinskii model for characterizing the rate-independent and rate-dependent hysteresis of piezoelectric actuators. Rev. Sci. Instrum. 2016, 87, 035002. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhi, Y.L.; Chen, J.S.; Huang, Y.C.; Wang, X.; Fan, X.G. Piecewise modified Prandtl-Ishlinskii model for precise nano-positioning. Instrum. Sci. Technol. 2024, 52, 516–535. [Google Scholar] [CrossRef] [Scilit]
- Yang, S.; Wang, W.; Wang, R.; Bao, L.; Wang, D.; Lu, K.; Chen, Z.; Wang, C. An improved dynamic Prandtl–Ishlinskii hysteresis model and a PID-type adaptive sliding mode controller for piezoelectric micro-motion platform. Smart Mater. Struct. 2024, 33, 075029. [Google Scholar] [CrossRef] [Scilit]
- Bao, L.; Wang, W.; Wang, R.; Yang, S.; Han, F.; Chen, Z.; Lu, K.; Wang, C. Research on parameter updating compensator for piezoelectric actuator based on modified dynamic Prandtl–Ishlinskii model. Smart Mater. Struct. 2025, 34, 10. [Google Scholar] [CrossRef] [Scilit]
- Al Janaideh, M.; Al Saaideh, M.; Tan, X. The Prandtl–Ishlinskii Hysteresis Model: Fundamentals of the Model and Its Inverse Compensator [Lecture Notes]. IEEE Control Syst. 2023, 43, 66–84. [Google Scholar] [CrossRef] [Scilit]
- Al Janaideh, M.; Rakotondrabe, M. Precision motion control of a piezoelectric cantilever positioning system with rate-dependent hysteresis nonlinearities. Nonlinear Dyn. 2021, 104, 3385–3405. [Google Scholar] [CrossRef] [Scilit]
- Zhu, R.; Liu, L.; Wu, Y.; Chen, H.; Lou, W.; Yang, P.; Kong, M. Modeling and parameter identification of rate-dependent hysteresis behavior based on modified-generalized Prandtl–Ishlinskii model. Smart Mater. Struct. 2024, 33, 075003. [Google Scholar] [CrossRef] [Scilit]
- Liu, D.; Dong, J.; Guo, S.; Tan, L.; Yu, S. Parameter Identification of Model for Piezoelectric Actuators. Micromachines 2023, 14, 1050. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, Q.; Dong, Y.; Peng, Y.; Luo, J.; Xie, S.; Pu, H. Asymmetric Bouc-Wen hysteresis modeling and inverse compensation for piezoelectric actuator via a genetic algorithm-based particle swarm optimization identification algorithm. J. Intell. Mater. Syst. Struct. 2019, 30, 1263–1275. [Google Scholar] [CrossRef] [Scilit]
- Feng, Y.; Li, Y. System Identification of Micro Piezoelectric Actuators via Rate-Dependent Prandtl-Ishlinskii Hysteresis Model Based on a Modified PSO Algorithm. IEEE Trans. Nanotechnol. 2021, 20, 205–214. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.M.; Liu, C.C.; Cai, M.L.; Shi, Y.; Gong, S.P.; Zhang, H.; Zhang, S.J. Force-displacement hysteresis characteristics of PAM based on improved generalised Prandtl-Ishlinskii model. Proc. Inst. Mech. Eng. Part C J. Mech. Eng. Sci. 2025, 239, 2512–2528. [Google Scholar] [CrossRef] [Scilit]
- Brest, J.; Sepesy Maučec, M. Comparative Study of Modern Differential Evolution Algorithms: Perspectives on Mechanisms and Performance. Mathematics 2025, 13, 1556. [Google Scholar] [CrossRef] [Scilit]
- Yuan, Z.X.; Zhou, S.L.; Zhang, Z.G.; Xiao, Z.Y.; Hong, C.L.; Chen, X.D.; Zeng, L.Z.; Li, X.Q. Piezo-actuated smart mechatronic systems: Nonlinear modeling, identification, and control. Mech. Syst. Signal Process. 2024, 221, 46. [Google Scholar] [CrossRef] [Scilit]
- Quaranta, G.; Lacarbonara, W.; Masri, S.F. A review on computational intelligence for identification of nonlinear dynamical systems. Nonlinear Dyn. 2020, 99, 1709–1761. [Google Scholar] [CrossRef] [Scilit]
- Tanabe, R.; Fukunaga, A.S. Improving the search performance of SHADE using linear population size reduction. In Proceedings of the 2014 IEEE Congress on Evolutionary Computation (CEC), Beijing, China, 6–11 July 2014; pp. 1658–1665. [Google Scholar] [CrossRef] [Scilit]
- Zhou, M.; Sun, Y.; Zhang, X.; Gao, W.; Zhang, X.; Su, C.Y. A Neural-Network-Based Practical Prescribed-Time Adaptive Nonlinear Controller and Its Application to a Piezoelectrically Actuated Micropositioning System. IEEE/ASME Trans. Mechatron. 2026. Early Access. [Google Scholar] [CrossRef] [Scilit]
- Zhou, M.L.; Sun, Y.L.; Zhang, X.Y.; Zhang, C.; Zhang, X.Y.; Gao, W.; Su, C.Y. Adaptive Practical Predefined-Time Control for Piezoelectric Micropositioning Platforms With Non-Fragile Prescribed Performance. IEEE Trans. Ind. Electron. 2026. Early Access. [Google Scholar] [CrossRef] [Scilit]
- Feng, Y.; Liang, M.W.; Li, Y. Adaptive Controller With Anti-Windup Compensator for Piezoelectric Micro Actuating Systems. IEEE Trans. Nanotechnol. 2024, 23, 45–54. [Google Scholar] [CrossRef] [Scilit]
- Al Janaideh, M.; Krejcí, P.; Monteiro, G.A. Memory reduction of rate-dependent Prandtl-Ishlinskii compensators in applications on high-precision motion systems. Physica B 2024, 677, 415595. [Google Scholar] [CrossRef] [Scilit]
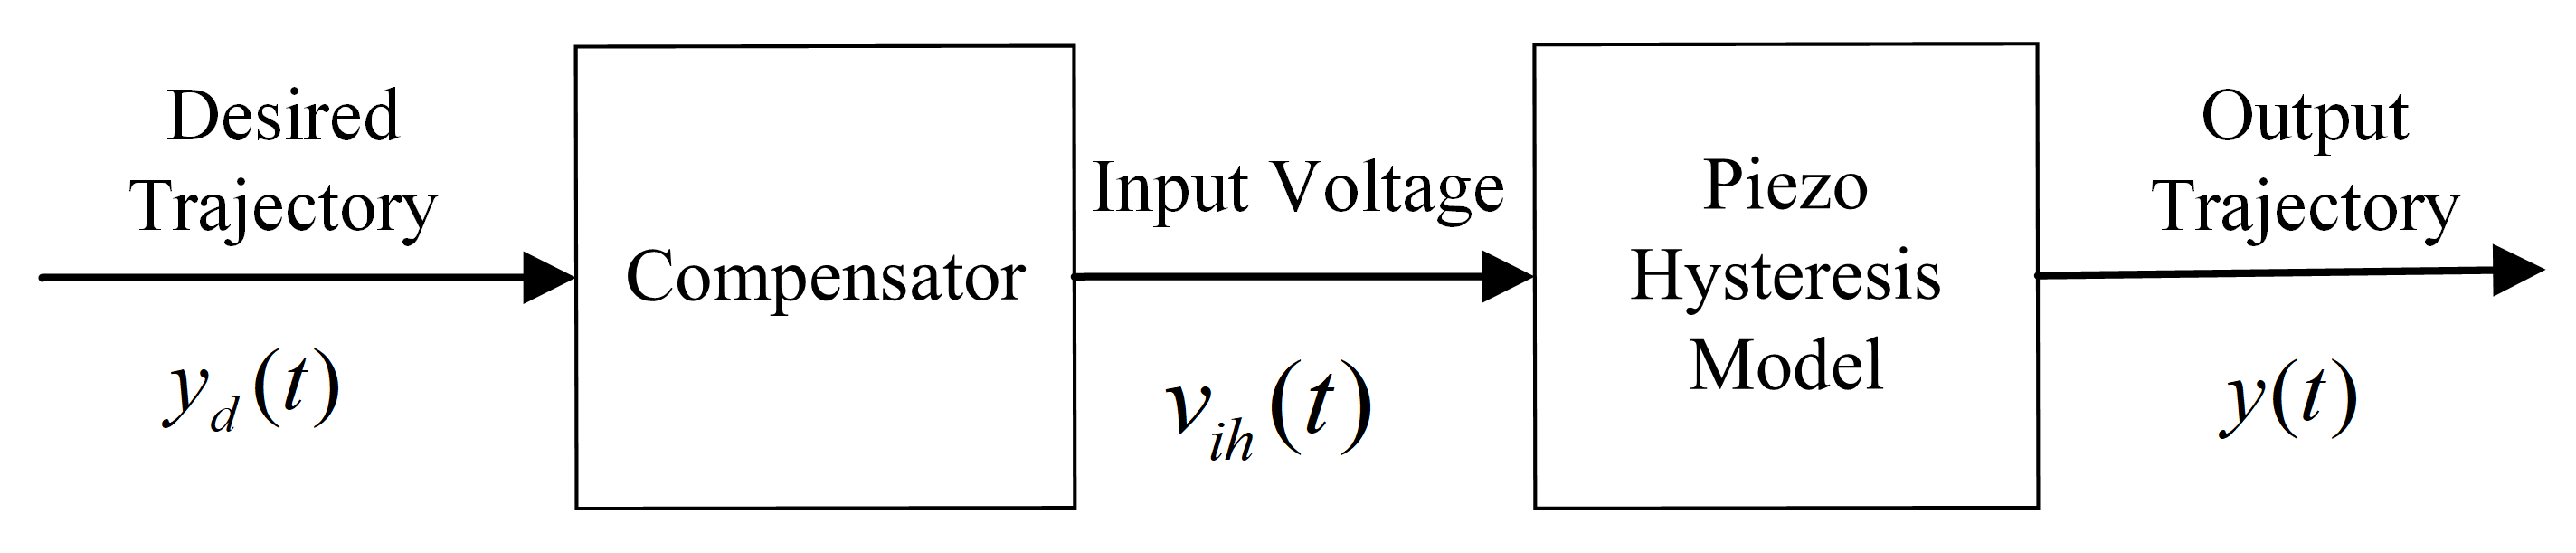

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.