


Abstract
Industry 5.0 challenges higher education to adopt human-centred and sustainable uses of artificial intelligence, yet many current deployments still treat generative AI as a stand-alone tool, neurophysiological sensing as largely laboratory-bound, and governance as an external add-on rather than a design constraint. This article introduces Nested Learning as a neuro-adaptive ecosystem design in which generative-AI agents, IoT infrastructures and multimodal deep learning orchestrate instructional support while preserving student agency and a “pedagogy of hope”. We report an exploratory two-phase mixed-methods study as an initial empirical illustration. First, a neuro-experimental calibration with 18 undergraduate students used mobile EEG while they interacted with ChatGPT in problem-solving tasks structured as challenge–support–reflection micro-cycles. Second, a field implementation at a university in Madrid involved 380 participants (300 students and 80 lecturers), embedding the Nested Learning ecosystem into regular courses. Data sources included EEG (P300) signals, interaction logs, self-report measures of engagement, self-regulated learning and cognitive safety (with strong internal consistency; ), and open-ended responses capturing emotional experience and ethical concerns. In Phase 1, P300 dynamics aligned with key instructional micro-events, providing feasibility evidence that low-cost neuro-adaptive pipelines can be sensitive to pedagogical flow in ecologically relevant tasks. In Phase 2, participants reported high levels of perceived nested support and cognitive safety, and observed associations between perceived Nested Learning, perceived neuro-adaptive adjustments, engagement and self-regulation were moderate to strong (–, ). Qualitative data converged on themes of clarity, adaptive support and non-punitive error culture, alongside recurring concerns about privacy and cognitive sovereignty. We argue that, under robust ethical, data-protection and sustainability-by-design constraints, Nested Learning can strengthen academic resilience, learner autonomy and human-centred uses of AI in higher education.
1. Introduction
Generative artificial intelligence (AI) chatbots (e.g., ChatGPT, Gemini, Claude) and ubiquitous Internet of Things (IoT) infrastructures are rapidly transforming higher education into an agent-mediated ecosystem [1,2,3,4,5,6,7]. While early deployments primarily targeted individual cognitive performance or administrative efficiency, the Industry 5.0 paradigm calls for human-centred, sustainable and resilient educational models in which technology not only instructs but also cares for learners [8,9]. In this view, AI systems should help maintain cognitive health, emotional balance and ethical awareness over time, especially in high-pressure academic environments [10,11]. We use the term Nested Learning to describe such environments: digital ecosystems that envelop students in layered support structures and treat errors not as failings but as opportunities for adaptive scaffolding [12,13].
In this article, Nested Learning is introduced as a new conceptual and design proposal, rather than as an already validated theory. We use the term to denote learning environments in which learners are surrounded by nested envelopes of support—human, artificial and contextual—that jointly modulate pacing, representation and difficulty over time. Nested Learning is thus not a generic label for any AI-enhanced course, but a specific configuration that: (i) integrates generative AI agents, neuroeducational protocols and smart-campus data in a unified orchestration layer; (ii) foregrounds cognitive safety, self-regulated learning and a Pedagogy of Hope as explicit sustainability goals; and (iii) treats learner trajectories as dynamical processes to be guided, rather than as static outcomes to be measured. The present study offers an initial operationalisation and exploratory empirical illustration of this proposal; future work will be needed to test and refine its boundaries across contexts.
Nested Learning is conceived as a neuro-adaptive ecosystem that integrates generative AI agents, campus IoT networks and neuroeducational protocols into a unified orchestration layer. At its core, the learner’s neurocognitive state (e.g., attention, cognitive load, affect) is continuously sensed through mobile electroencephalography (EEG) and interaction traces, and then coupled with the external instructional context in real time [14,15,16,17]. In this work, the P300 component is used as a key attentional marker, embedded within dedicated neuroeducational protocols (PRONIN and SIEN) that structure sessions into micro-events and map instructional phases to neurophysiological windows [12]. This coupling enables the ecosystem to modulate pacing, representation and task difficulty in response to measurable changes in students’ cognitive states.
In parallel, multimodal learning analytics and deep learning have broadened the range of signals available to educators, from keystroke and clickstream data to affective cues and biosignals [18,19,20]. Recent reviews on AI in education and intelligent tutoring emphasise substantial progress in automated support and personalisation, but also highlight the lack of integrative frameworks that connect multimodal sensing, adaptive policies and ethical governance in a single model [13,21,22]. Most current applications either (i) use generative AI as a standalone tool for content generation or feedback, or (ii) treat neuroimaging within tightly controlled laboratory settings that are difficult to scale to authentic classrooms [2,3]. There remains a gap between these strands: we lack conceptual and technical frameworks that jointly orchestrate generative AI agents, multimodal deep learning and neurophysiological sensing in ways that are transparent, reproducible and aligned with educational values such as autonomy, equity and sustainability [9,23] particularly in ways that can be audited by educators, replicated across courses, and constrained by privacy-by-design requirements when neurocognitive signals are included.
Recent empirical syntheses indicate that the adoption of generative AI in higher education remains predominantly fragmented and user-driven. Rather than being systematically integrated, LLMs are often appropriated by students and educators as individual assistants for drafting, explaining, coding, or feedback, frequently lacking alignment with course-level instructional design, assessment formats, and institutional governance. This “bolt-on” phenomenon is corroborated by systematic reviews of ChatGPT-in-education research, which associate such usage with perceived learning benefits while highlighting persistent concerns regarding transparency, dependency, and algorithmic fairness [24].
Concurrently, reviews of mobile and classroom neuroimaging reveal that while ecologically valid measurement is advancing, it remains comparatively sparse, methodologically heterogeneous, and difficult to scale. Classroom-based EEG studies face non-trivial implementation challenges—ranging from motion artefacts and variable task structures to limited protocol standardisation and privacy constraints—explaining the continued reliance on controlled paradigms. Consequently, recent scoping reviews emphasize the critical need for integrative frameworks that can harmonise portable sensing and learning analytics with interpretable adaptive policies under robust ethical governance [25,26].
Alongside these optimistic narratives, a substantial body of critical scholarship warns that AI in education can intensify datafication, commercialisation and automation of pedagogical decisions, with problematic implications for equity, professional autonomy and student agency [27,28,29,30,31,32]. Our work is explicitly situated at this intersection: Nested Learning is proposed not as a neutral technical fix, but as a design framework that must be evaluated against these concerns, particularly in relation to cognitive safety, data governance and sustainable workloads for teachers and students.
Study-design note (neuro–field integration). To address this gap, we adopt a two-phase mixed-methods design that calibrates the Nested Learning ecosystem in a laboratory setting and then evaluates it at scale in authentic courses [33]. As summarised in Table 1, a first neuro-experimental phase with biomedical undergraduates uses mobile EEG (Emotiv EPOC+, EMOTIV Inc., San Francisco, CA, USA; 14 channels, 128 Hz) during problem-solving tasks mediated by ChatGPT to examine whether P300 dynamics and derived neuroeducational indices are sufficiently sensitive and stable under the proposed protocol to justify larger-scale studies [14,15]. This phase is explicitly conceived as an exploratory calibration study rather than a fully powered validation of the neuro-adaptive system. A second field phase in a Madrid-based university involves participants (300 students, 80 lecturers), embedding the ecosystem into regular courses with multiple generative AI platforms (ChatGPT, Gemini, Claude, Copilot, DeepSeek, GPT-o1) orchestrated through distributed-agent frameworks (JADE, PADE, LangChain) and connected to the campus IoT infrastructure. This combination allows us to study both the neurophysiological underpinnings of Nested Learning and its perceived impact on engagement, self-regulation, cognitive safety and ethical concerns in real-world contexts. Figure 1 provides a temporal overview of the two phases.
Table 1.
Overview of the two-phase mixed-methods design underpinning the Nested Learning ecosystem.
Figure 1.
Temporal overview of the two-phase mixed-methods design underlying the Nested Learning ecosystem. Phase 1 provides an exploratory calibration of the neuro-adaptive pipeline; Phase 2 evaluates its pedagogical and ethical impact in authentic courses.
Beyond the technical challenge, AI-mediated higher education raises a broader pedagogical question: what forms of knowledge, agency and wellbeing should be valued when AI can already produce sophisticated outputs on demand? From a sustainability perspective, focusing solely on product quality (grades, performance metrics) is insufficient. Sustainable higher education requires attention to students’ capacity for self-regulated learning, their experience of cognitive safety and their sense of hope and meaning in the learning process [10,11,23]. We therefore position Nested Learning within a “Pedagogy of Hope” perspective, in which AI and neuroadaptive technologies are used to expand, rather than erode, human agency—particularly for students who are at risk of disengagement, burnout or marginalisation [12,13,34,35,36,37,38,39].
In this framing, the role of generative AI agents extends beyond delivering feedback or solving tasks. Agents become mediators of process visibility: they expose planning traces, testing strategies, evidence citations and neuro-adaptive adjustments in ways that students and teachers can inspect and critique [2,3,9,40,41,42]. The IoT layer enriches this picture by bringing contextual signals from physical spaces (e.g., classroom occupancy, environmental conditions) into the decision loop, supporting more holistic understandings of when and why learners thrive or struggle [5]. Figure 2 provides a high-level overview of this multi-layer ecosystem and its multimodal data pipeline, while Figure 3 situates Nested Learning conceptually at the intersection of generative AI, neuroeducation and sustainable higher education.
Figure 2.
Conceptual view of the Nested Learning ecosystem. (a) Multi-layer architecture surrounding the learner, from neurocognitive states to AI agents, smart-campus infrastructure and governance. (b) Multimodal neuro-adaptive pipeline that integrates EEG, interaction and contextual data through deep learning models to inform agent policies and educational outcomes.
Figure 3.
Conceptual positioning of Nested Learning at the intersection of generative AI, neuroeducation and sustainable higher education.
To make the study design transparent, Table 1 summarises the two phases and their main characteristics.
This study introduces Nested Learning as a neuro-adaptive, agent-mediated ecosystem for sustainable higher education. Our contribution is fourfold:
- (i)
- Conceptually, we articulate Nested Learning as a multi-layer architecture that integrates generative AI, neuroeducation and IoT within a Pedagogy-of-Hope framework, positioning cognitive safety, resilience and autonomy as explicit sustainability goals [8,9,12].
- (ii)
- Methodologically, we propose a multimodal deep-learning pipeline that aligns EEG (P300) dynamics with instructional events and agent interventions, enabling neuro-adaptive policies that remain interpretable for educators [14,15,16,17].
- (iii)
- Empirically, we provide preliminary findings from a two-phase mixed-methods design: a neuro-experimental calibration with students and a field implementation with participants, focusing on engagement, self-regulated learning, perceived clarity, adaptive support and ethical concerns [11,23,33].
- (iv)
- From a governance perspective, we discuss how privacy-by-design, data sovereignty and ethical stewardship are necessary to deploy Nested Learning ecosystems in ways that are compatible with sustainable higher education and the broader goals of Industry 5.0, while responding to critical concerns about datafication and automation in AI in education [5,9,27,31,42,43,44].
As illustrated in Figure 4, Figure 5 and Figure 6, the proposed Nested Learning ecosystem combines low-cost neuroimaging, real-time interaction with generative AI agents, and a multi-platform LLM workstation deployed in authentic higher-education settings.
Figure 4.
Instant of the neuroadaptive Nested Learning session in the EEG lab. A student wears a low-cost 14-channel Emotiv EPOC+ headset while real-time cortical activity and brain topographies are displayed on multiple monitors.
Figure 5.
Use of ChatGPT together with real-time EEG reading and P300 visualization during a Nested Learning activity. The left side of the screen shows the interaction with the generative AI agent, while the right side displays event-related potentials and cortical maps used to monitor attentional dynamics.
Figure 6.
Multi-agent generative-AI station used in the large-scale phase of the study, integrating six platforms (ChatGPT, Gemini, Claude, Copilot, DeepSeek and GPT-o1) in a single workspace. This photograph illustrates the practical implementation of the Nested Learning ecosystem in a real university setting.
Core contribution. This paper proposes Nested Learning as a policy-aware orchestration framework for AI-rich higher education: rather than treating generative AI as a stand-alone tool, Nested Learning coordinates layered supports (teacher–agents–peers–context) under explicit governance constraints to sustain engagement, self-regulation, and cognitive safety over time [45,46]. Our empirical contribution is feasibility-oriented (Phase 1) and ecological/associational (Phase 2), aiming to test compatibility with the framework rather than causal effectiveness.
To clarify how Nested Learning departs from adjacent AIED and learning-analytics paradigms, we position its distinctive contributions against related approaches (Table 2).
Table 2.
How Nested Learning differs from adjacent AIED/learning-analytics approaches (conceptual summary).
Research questions and hypotheses.
- RQ1 (Feasibility). Can low-cost mobile EEG capture interpretable event-locked attentional markers aligned with Nested Learning micro-events in an ecologically plausible scripted task?
- H1. Nested Learning segments/events are associated with higher P300 amplitude (and a higher probability of high-P300 epochs) than baseline segments in Phase 1 (exploratory calibration).
- RQ2 (Field perception). In authentic higher-education courses, how are perceived Nested Learning (NL) and perceived neuroadaptive adjustments (NA) associated with engagement (ENG) and self-regulation (SRL)?
- H2. NL and NA are positively associated with ENG and SRL (observational, cross-sectional evidence).
- RQ3 (Governance tension). What boundaries of personalisation are perceived as acceptable when balancing adaptivity against privacy and cognitive sovereignty?
2. Theoretical Framework
This section outlines the theoretical foundations that inform the Nested Learning ecosystem. We organise the framework into four interrelated strands: (i) Nested Learning and the Pedagogy of Hope; (ii) multimodal deep learning and neuroimaging; (iii) agent-based generative AI and IoT infrastructures; and (iv) the integration of neurotheoretical, neuromethodological and neurodidactic perspectives. Figure 7 provides a synthetic overview of how these strands converge, and Table 3 summarises how they are operationalised in the present study.
Figure 7.
Theoretical integration of the Nested Learning ecosystem. Micro-level neurocognitive states are modelled by multimodal and P300-based analytics; meso-level instructional episodes are orchestrated by generative AI agents; macro-level institutional and sustainability policies constrain and enable deployment. These levels jointly support sustainable higher-education outcomes.
Table 3.
Synthesis of the theoretical framework and its operationalisation in the present study.
2.1. Nested Learning and the Pedagogy of Hope
We conceptualise Nested Learning as the capacity of an educational ecosystem to envelop learners in a layered structure of cognitive, emotional and ethical support, while preserving their autonomy and agency. This notion is aligned with Freirean traditions of critical pedagogy and the Pedagogy of Hope, which emphasise dialogic relationships, co-construction of meaning and the refusal to naturalise exclusion or failure [12,13,34,35]. In a Nested Learning environment, mistakes are treated as diagnostic signals that trigger adaptive scaffolds rather than as terminal judgements, and learners are invited to interpret AI outputs critically rather than passively accepting them. This stance is increasingly relevant in the context of generative AI, where recent guidance stresses transparency, critical engagement and responsible use in educational settings [5,6].
Why an Integrated Framework Is Still Missing
Recent evidence syntheses indicate that, despite rapid uptake, most generative-AI deployments in higher education remain tool-centric and standalone: they focus on prompt-based content generation, writing support, or ad hoc tutoring, often without an explicit integration of multimodal sensing, adaptive policy design, and institution-level governance [24,47]. Systematic and scoping reviews on ChatGPT and generative AI in higher education report a predominance of isolated use cases and short-term outcomes, while explicitly calling for frameworks that connect pedagogical scripts, accountability, and ethical safeguards [36,37,39]. In parallel, reviews on AI in education highlight recurring gaps in transparency, teacher workload sustainability, and the alignment between personalisation mechanisms and human-centred values [40,41]. Nested Learning is positioned as a response to this missing integration: it treats orchestration, care, and governance as first-class design variables rather than downstream concerns.
From a neuroeducational standpoint, this orientation resonates with research showing that learning is tightly coupled to emotional and social experience [10,13]. Feelings of safety, belonging and hope modulate attention, memory consolidation and self-regulated learning (SRL), especially in high-stakes contexts [11]. SRL frameworks further highlight the importance of metacognitive monitoring, strategic planning and reflective evaluation as learners navigate complex tasks [23]. In Nested Learning, these SRL processes are not only internal; they are distributed across learners, peers, educators and AI agents, forming a socio-technical network that supports planning, feedback and reflection over time [3,19].
Critically, Nested Learning is also informed by the critical literature on AI in education, which warns against unexamined datafication, commercialisation and automation of pedagogical decisions [27,28,29,30,31,32]. Rather than assuming that more sensing and more AI are inherently beneficial, the framework treats neuro-adaptive capabilities as tools that must be constrained by human-centred values and institutional governance. We therefore interpret Nested Learning as a design stance with three key implications: (i) relational, in that learners are embedded in supportive human and technological relationships; (ii) temporal, in that learning trajectories are followed over extended periods instead of being reduced to single assessments; and (iii) ethical, in that the ecosystem is explicitly oriented towards inclusion, dignity and sustainability in line with Industry 5.0 principles [8,9]. These implications guide the construction of our neuroadaptive ecosystem and its evaluation in higher education.
2.2. Multimodal Deep Learning and Neuroimaging
To operationalise the “nesting” of support, the system must perceive and interpret the learner’s state through multiple channels. Multimodal learning analytics brings together digital interaction traces (clicks, keystrokes, navigation patterns), physiological signals (e.g., heart rate, skin conductance) and behavioural cues (e.g., gaze, posture) to model engagement and cognitive load [18,19,20]. Recent advances in deep learning enable the joint modelling of such heterogeneous data streams, capturing temporal dependencies and non-linear interactions that are difficult to express in traditional models.
In this work, EEG plays a central role within the multimodal pipeline. Mobile headsets such as Emotiv EPOC+ allow the recording of cortical dynamics in authentic educational settings, albeit with lower spatial resolution than clinical devices. We focus on the P300 component of the event-related potential (ERP), a well-established marker of attention and context updating that typically emerges 250–500 ms after salient stimuli [16,17]. When embedded in structured protocols that align experimental events with pedagogical micro-tasks, P300 dynamics can index the extent to which learners detect and process critical information [14,15].
2.2.1. From Laboratory Neuroimaging to Ecologically Valid Measurement
Educational neuroimaging has historically relied on laboratory paradigms due to signal quality constraints, controlled timing requirements, and the complexity of artefact management. Recent reviews nonetheless show a growing, but still methodologically heterogeneous, body of work using mobile or wearable EEG in more naturalistic learning settings, while emphasising that reproducibility depends on transparent artefact-handling protocols and well-defined event structures [25,26]. Nested Learning adopts this implication explicitly: the neuroeducational protocols (PRONIN and SIEN) are designed to time-lock instructional micro-events to EEG windows, reducing ambiguity in the mapping between pedagogy and neurophysiology and supporting interpretability [12].
2.2.2. Disciplinary Specificity and Neurobiological Indicators
Importantly, neurocognitive markers such as attentional dynamics should not be assumed invariant across disciplinary cultures and professional trajectories. Emerging evidence in authentic university contexts suggests that interactional and neural dynamics can differ by discipline, motivating caution when generalising findings from a single programme and highlighting the need for cross-disciplinary replications [38]. In Nested Learning, this motivates treating the measurement and policy layers as context-conditional: both the observation function and the action policy are assumed to depend on contextual covariates (including disciplinary context) rather than reflecting a one-size-fits-all neuroadaptive profile.
Recent work on EEG-based adaptive learning has shown that neural markers of workload, attention and engagement can be used to modulate task difficulty, feedback timing or multimedia presentation in real or near-real time [14]. However, most studies operate in tightly constrained scenarios (e.g., single-task training, laboratory-based interfaces) and rarely involve generative AI. Our neuroeducational protocols (PRONIN and SIEN) specify sequences of tasks, prompts and feedback episodes that are time-locked to EEG markers, enabling a principled coupling between the instructional script and neurophysiological responses [12]. Within the multimodal deep-learning layer, P300 amplitudes and latencies are combined with interaction logs and contextual features to generate state representations that can inform neuro-adaptive policies. These policies remain interpretable for educators, who can relate changes in attention and engagement to concrete instructional events rather than to opaque numerical scores [13].
2.3. Agent-Based Generative AI and IoT
Generative AI systems—particularly large language models (LLMs)—are increasingly used to provide feedback, explanations and examples in higher education [3,5,7]. However, single-agent configurations often operate as black boxes and are difficult to embed into broader pedagogical workflows. Recent work on retrieval-augmented generation (RAG) and agentic orchestration has proposed architectures in which multiple specialised agents collaborate, each with access to tools, external knowledge bases and evaluation routines, making intermediate reasoning steps and evidence sources explicit. Such architectures are increasingly discussed together with institutional guidance on transparency, accountability and responsible deployment of generative AI in education [6].
In the Nested Learning ecosystem, we adopt an agent-based architecture in which different LLM-based agents are responsible for functions such as task decomposition, formative feedback, ethical guidance and data-governance monitoring. Agents are instantiated across several commercial and open platforms (ChatGPT, Gemini, Claude, Copilot, DeepSeek, GPT-o1), orchestrated through frameworks such as JADE, PADE and LangChain, and instrumented via logging for research purposes. The multi-agent station depicted in Figure 6 exemplifies this design and aligns with proposals for AI “orchestrators” in education [1,3]. Recent reviews additionally stress that, without explicit role design and accountability mechanisms, multi-agent AI can amplify opacity and workload, reinforcing the need for auditable orchestration and governance-by-design [36,41].
The IoT and smart-campus layer complements the agent infrastructure by providing contextual data from physical spaces: occupancy sensors, environmental measurements and device telemetry. These signals inform decisions about pacing, modality and timing (e.g., slowing down activities during periods of high noise or overload, or suggesting asynchronous reflection when cognitive fatigue is detected). By connecting generative AI agents to IoT streams, the system can coordinate actions across digital and physical environments, making Nested Learning a truly cyber-physical ecosystem and extending classical adaptive tutoring and AIED models towards whole-campus, sustainability-oriented deployments [21,22].
2.4. Neurotheoretical, Neuromethodological and Neurodidactic Integration
The final strand of the framework concerns the integration of theoretical, methodological and didactic levels. Neurotheoretically, our work is grounded in models that link attention, prediction and emotion to learning, including theories of context updating, predictive coding and affective modulation of cognition [10,11,16]. Neuromethodologically, we align EEG protocols, behavioural tasks and self-report measures in a convergent mixed-methods design, combining laboratory calibration with ecological deployment in real courses [13,15,33]. Neurodidactically, we translate these insights into concrete instructional patterns (e.g., micro-cycles of challenge–support–reflection) that can be orchestrated by AI agents while remaining legible and adjustable for teachers [12].
Figure 7 situates these three levels—neurotheoretical, neuromethodological and neurodidactic—within the broader Nested Learning ecosystem. At the micro level, individual learners’ neurocognitive states are modelled through P300 and multimodal signals. At the meso level, instructional episodes and AI-mediated interactions implement adaptive strategies grounded in SRL and Pedagogy-of-Hope principles. At the macro level, institutional policies, data-governance frameworks and sustainability agendas constrain and enable how the ecosystem can be deployed [6,8,9]. Table 3 synthesises how these levels map onto concrete constructs and indicators in the present study.
2.5. Mathematical Framing of Nested Learning Dynamics
Beyond the conceptual and neuroeducational arguments, the Nested Learning ecosystem can be viewed as a discrete-time dynamical system that updates learners’ states in response to AI-mediated and human-mediated support. Formalising this perspective helps clarify which parameters are responsible for growth, saturation and potential inequalities, in line with prior work on algorithmic models of feedback and learning trajectories.
Let i index learners and index instructional episodes (e.g., task cycles or neuroeducational segments). We define a latent state vector
where denotes task-related performance (product quality), engagement, self-regulated learning (SRL) and perceived cognitive safety. The range represents normalised indices relative to pedagogical targets.
During episode t, the Nested Learning ecosystem applies an intervention or action chosen by educators and/or AI agents (e.g., changing difficulty, modality or pacing). We summarise the effective support quality on each dimension by a vector
where depends on the current state, the action and contextual conditions (e.g., classroom density, time pressure, environmental noise).
2.5.1. Component-Wise Logistic Update
For each dimension , we posit a discrete-time update of the form
where controls growth in response to high-quality support, captures decay or erosion in the absence of such support, and is a zero-mean disturbance term representing unmodelled factors. When is high and is far from 1, the first term dominates and the state grows; when support is weak and the state is high, the second term dominates and the state can regress. Equation (3) thus generalises logistic growth with forgetting and aligns with prior models for iterative learning under feedback [22].
In vector notation, the state dynamics are governed by
where and denote learner-specific parameter vectors, ⊙ represents the Hadamard (element-wise) product, and is a vector of ones. Analytically, examining the increments
enables the characterisation of empirical convergence patterns—such as diminishing returns near saturation or differential growth across dimensions S, E, R, and C—and relates them to both support quality and individual parameter profiles.
2.5.2. Neuro-Adaptive Measurement Model
Since the latent state remains unobservable, the system relies on a multimodal observation vector defined as
where comprises EEG features (including P300 amplitudes and latencies), captures behavioural traces (logs, timings, error patterns), and represents self-report scores (e.g., engagement, SRL, cognitive safety). We posit a measurement model
where is implemented via multimodal deep learning architectures (e.g., recurrent or attention-based models) [20], and denotes residual noise. Specifically for the P300 component, we model the relationship between attentional state and ERP amplitude using a linear mixed-effects formulation:
where encodes the task condition (e.g., baseline vs. Nested Learning), is a learner-specific random intercept, and is the error term [14,16]. Alternatively, in a probabilistic framework, the likelihood of observing a high-amplitude P300 response is given by
where is the logistic function. Equations (8) and (9) formalise the hypothesis that heightened engagement and cognitive safety correlate with distinct attentional signatures within Nested Learning protocols.
2.5.3. Policy-Level View
From an agent-based perspective, Equations (4)–(7) constitute a partially observed Markov decision process (POMDP) defined over learner states. At each time step, the orchestrator updates a state estimate (e.g., via filtering or recurrent encoders) and selects an action according to a policy
The objective is to maximise long-term sustainable outcomes—modelled as a weighted combination of , , , and —while strictly adhering to ethical and governance constraints [6,9]. While a comprehensive reinforcement-learning analysis is outside the scope of this work, the dynamical system presented in Equations (3) and (4) provides a rigorous foundation for analysing convergence, sensitivity to intervention quality, and potential disparities arising from diverse parameter profiles . This mathematical formulation serves as a conceptual scaffold rather than a fully identified model for this study. It complements the qualitative and neuroeducational perspectives by explicating Nested Learning as a controlled process over multi-dimensional states, driven by neuro-adaptive observations and regulated by policy design within the generative-AI and IoT layers.
3. Materials and Methods
3.1. Overall Research Design
The study followed a mixed-methods design combining a neuro-experimental phase and a large-scale field implementation in higher education. Quantitative and qualitative strands were articulated within an interpretivist paradigm, allowing us to examine both neurophysiological sensitivity to Nested Learning interventions and participants’ lived experience of the ecosystem in situ [13,33]. As summarised in Table 1, Phase 1 focused on the calibration of neuro-adaptive markers under controlled conditions, whereas Phase 2 examined perceived Nested Learning, interaction with generative AI, perceived neuroadaptive adjustments and the climate of hope and cognitive safety in a real university context. In line with recent guidance on generative AI in education, our design explicitly treats transparency, accountability and data governance as methodological constraints rather than as post-hoc considerations [5,6,7].
3.2. Sample Size and Power Considerations
Phase 1 was designed as a neuro-experimental calibration and feasibility study rather than as a definitive validation of the neuro-adaptive system. The sample size of was determined pragmatically, balancing laboratory capacity, time constraints and the intensive nature of EEG-based protocols, and is consistent with typical sample sizes in within-subject ERP studies that focus on detecting medium-to-large effects in P300 amplitude and latency [14,16]. No formal a priori power analysis was conducted; consequently, Phase 1 is underpowered for small effects and its results are interpreted as sensitivity checks and proof-of-concept evidence, not as normative benchmarks.
Phase 2 was conceived as a field study to explore how the Nested Learning ecosystem is perceived in authentic higher-education contexts. The resulting sample of participants (300 students, 80 lecturers) exceeds common rules of thumb for factor-analytic work (e.g., a minimum of 5–10 participants per item) and is adequate for the psychometric analyses reported in Section 4 [13]. Nonetheless, both phases should be considered as initial empirical instantiations of the framework, and future work with larger and more diverse samples is needed to refine and stress-test the proposed models.
3.3. Phase 1: Neuro-Experimental Calibration
3.3.1. Participants and Context
The neuro-experimental phase used a quantitative, experimental design with undergraduate students enrolled in the fourth year of a biomedical degree (age range 21–24 years). Participants were recruited via email announcements and classroom visits and volunteered to take part in a laboratory session focused on problem-solving tasks mediated by ChatGPT, under a Nested Learning protocol that alternated segments of challenge, scaffolded support and reflection. Inclusion criteria were enrolment in the degree, absence of diagnosed neurological conditions and normal or corrected-to-normal vision; no monetary incentives were provided.
Disciplinary specificity (methodological scope). Because Phase 1 was explicitly conceived as a calibration study for neuro-adaptive sensitivity, we intentionally used a homogeneous disciplinary cohort (biomedical senior undergraduates) and domain-consistent tasks to reduce uncontrolled variance in prior knowledge, epistemic practices and task familiarity. This design choice improves internal consistency for sensitivity checks (P300 alignment with micro-events) but also limits the generalisability of Phase 1 to other disciplinary cultures. To partially mitigate this limitation at the study level, Phase 2 included participants from STEM and non-STEM programmes and collected programme-related covariates (Section 3.4) that were used in subsequent analyses.
To partially control for potential confounders, sessions were scheduled in late morning or early afternoon, avoiding extreme times of day. Before the EEG setup, participants completed a brief self-report checklist on sleep quality, perceived fatigue and stress level on the day of the experiment. Participants who reported acute illness or extreme sleep deprivation were rescheduled. Within sessions, short breaks were offered between blocks to mitigate fatigue, and task order was counterbalanced across participants to reduce systematic ordering effects.
Sessions took place in a university neuroscience laboratory equipped with an EEG recording station, multiple display screens and controlled ambient conditions (lighting, noise, seating). Each session lasted approximately 45–60 min and followed a scripted sequence including: (i) baseline rest, (ii) instruction and calibration, (iii) task blocks with ChatGPT-mediated problem solving, and (iv) reflective segments with explicit prompts aligned to the Pedagogy-of-Hope principles in Section 2.1. The objective of Phase 1 was to calibrate the sensitivity of P300 and related EEG markers to instructional micro-events orchestrated under the Nested Learning paradigm, acknowledging that the small sample size limits generalisability.
3.3.2. Task Script and Event Structure
The experimental script defined a sequence of problem-solving tasks grounded in domain-relevant biomedical scenarios (e.g., interpreting simplified clinical cases, reasoning about physiological mechanisms, comparing alternative treatment rationales). Each task consisted of several steps: initial case presentation, prompting the student to propose a hypothesis or explanation, interaction with ChatGPT to obtain feedback or alternative viewpoints, and a brief reflective prompt asking the student to justify or revise their reasoning.
Within this script, we defined micro-events as pedagogically meaningful units that could elicit discrete attentional responses: (i) onset of a new case or key piece of information; (ii) display of an AI-generated explanation or hint; (iii) explicit feedback highlighting an error or misconception; and (iv) reflective prompts explicitly inviting the student to reconsider or extend their answer. Events were tagged according to dimensions such as novelty (new vs. repeated information), cognitive demand (low vs. high), and explicitness of feedback (implicit vs. explicit). These tags were later used as predictors in the P300 models in Equations (8) and (9).
Pedagogical events and ChatGPT interactions were coordinated through a central controller that sent time-stamped messages to an Apache Kafka bus. Each message encoded the event type, its pedagogical intensity and the current phase of the Nested Learning micro-cycle (challenge, support, reflection). Figure 8 summarises the end-to-end pipeline for Phase 1.
Figure 8.
End-to-end pipeline for Phase 1. Pedagogical events and ChatGPT interactions are scripted and pushed to a Kafka bus, which synchronises event markers with EEG acquisition. Data are preprocessed, P300 features are extracted and statistical models are estimated to calibrate the neuro-adaptive sensitivity of the Nested Learning ecosystem.
3.3.3. EEG Acquisition and Synchronisation
Cortical activity was recorded using a low-cost Emotiv EPOC device with 14 channels, sampling at 128 Hz and with a semi-standard electrode placement aligned with the international 10–20 system. Data acquisition software subscribed to the Kafka topics carrying event markers and wrote event codes into the EEG stream as auxiliary channels, ensuring millisecond-level synchronisation between pedagogical stimuli and brain signals.
Signal quality was monitored in real time using manufacturer-provided indicators (contact quality) and visual inspection. If one or more channels consistently failed to reach acceptable quality, the headset was re-adjusted before continuing. Sessions with pervasive poor signal quality were terminated and data excluded from analysis; the number of excluded sessions and retained participants is reported in Section 4.
3.3.4. Preprocessing, Artefact Handling and Feature Engineering
EEG preprocessing followed standard guidelines for ERP research in applied and mobile settings [14,16]. To facilitate reproducibility, we specify below the parameterisation used for filtering, channel-level quality control, ICA configuration, and artefact rejection thresholds.
Filtering and Channel-Level Quality Control
Signals were (i) band-pass filtered between 0.1 Hz and 30 Hz (zero-phase FIR) and (ii) notch filtered at 50 Hz to remove line noise. Continuous recordings were screened for channel-level artefacts using a combined criterion: channels were flagged as “bad” if they exhibited (a) persistently poor contact quality during acquisition, and/or (b) abnormally high variance (>3 SD above participant-specific median) or frequent flat segments (>2 s). Bad channels were excluded from ICA estimation and then reconstructed by spherical-spline interpolation from the remaining channels when at least 10 channels were available; otherwise, the participant was retained only if sufficient clean epochs were available after epoch-level cleaning. After artefact handling, data were transformed to an average reference for analysis (noting that the device uses a proprietary reference scheme during acquisition).
Epoching and Baseline Correction
Signals were segmented into epochs from ms to ms around event onsets and baseline-corrected using the pre-stimulus interval ( to 0 ms). Epochs were time-locked to Kafka markers to preserve alignment between pedagogical micro-events and neurophysiological windows.
ICA Configuration for Ocular and Muscular Artefacts (Replicable Protocol)
When signal quality allowed, ICA was applied to attenuate ocular (EOG-like) and muscle (EMG-like) contamination. ICA was computed on continuous data using an extended Infomax decomposition (component count = number of retained channels; maximum iterations = 512; convergence tolerance = ). To improve decomposition stability, ICA estimation was performed on a copy of the data high-pass filtered at 1 Hz (a common practice in ERP pipelines); the resulting unmixing matrix was then applied to the 0.1–30 Hz data used for feature extraction. Components were classified using a hybrid criterion combining (i) topography and time-course inspection, (ii) spectral signatures (ocular: dominant low-frequency activity; muscle: elevated high-frequency power), and (iii) automated labels when available (e.g., IC classifiers). Components were removed if they met at least one of the following criteria:
- Ocular criterion: clear frontal topography and blink/saccade-like transients, and/or classifier “eye” probability ;
- Muscle criterion: localised/scattered topography with elevated 20–40 Hz power, and/or classifier “muscle” probability ;
- Correlation criterion: absolute correlation between the component time course and frontal channels (proxy for blink activity) across the continuous segment.
To avoid overcorrection with low-density EEG, a maximum of three components per participant were removed unless visual inspection clearly indicated pervasive artefact. If ICA quality was insufficient (e.g., non-convergence, unstable decomposition, or >30% of components flagged), ICA was not applied and the pipeline relied on epoch-level rejection thresholds instead.
Epoch-Level Artefact Rejection Thresholds
After ICA (when applied), epochs were screened using semi-automatic thresholds defined a priori:
- absolute amplitude exceeding in any channel;
- peak-to-peak amplitude within the epoch;
- maximum step (sample-to-sample) (indicative of abrupt movement artefacts);
- baseline drift exceeding in the to 0 ms window.
Threshold-based rejection was complemented by visual inspection for residual non-stereotyped artefacts. For each participant and condition, we required a minimum of 20 clean epochs per event type to retain data for analysis; where the count dropped below this threshold, that event type was excluded for that participant. The proportion of discarded epochs per participant and condition is summarised in Section 4.
Feature Extraction
P300 features were extracted at posterior channels corresponding to Pz in the Emotiv configuration, focusing on the 250–400 ms post-stimulus window [16,17]. For each participant and event type, we computed: (i) mean P300 amplitude () in the 250–400 ms window; (ii) P300 peak latency (ms) within the same window; and (iii) binary indicators of “high P300” responses using participant-specific thresholds (amplitude exceeding participant mean + one standard deviation). Algorithm 1 summarises the processing pipeline for a single participant; all parameter values above apply uniformly across participants to support reproducibility.
For transparency and reproducibility, the full set of EEG preprocessing parameters and artefact-handling thresholds used in Phase 1 is summarised in Table 4.
| Algorithm 1 Phase 1 EEG preprocessing and P300 feature extraction pipeline. |
|
Table 4.
Key EEG preprocessing parameters and artefact-handling thresholds (Phase 1).
3.3.5. Statistical Modelling of P300 Sensitivity
P300 features were analysed using linear and logistic mixed-effects models aligned with Equations (8) and (9). For amplitude, we estimated models of the form
where captured pedagogical descriptors (e.g., novelty, demand), distinguished Nested Learning segments from baseline conditions, was a participant-level random intercept and an error term [14,16]. For high-P300 probability, we used logistic mixed models
with a random intercept. These models provide empirical estimates for the parameters in Equations (8) and (9), anchoring the measurement model in observed data. Given the limited sample size, these analyses are treated as exploratory–confirmatory probes of sensitivity rather than as definitive tests of complex interaction structures.
3.4. Phase 2: Field Implementation in Higher Education
Participants, Courses and Ecosystem Deployment
Phase 2 was conducted at a university in Madrid through the deployment of the Nested Learning ecosystem in regular higher-education courses. A total of participants took part, comprising 300 students and 80 lecturers from diverse degree programmes (STEM and non-STEM). Participation was voluntary and integrated into ordinary teaching activities; no changes were made to official grading schemes.
The ecosystem was implemented by integrating six generative-AI platforms (ChatGPT, Gemini, Claude, Copilot, DeepSeek and GPT-o1) into a unified multi-agent station, orchestrated through JADE, PADE and LangChain, and connected to the campus IoT infrastructure. Each AI platform instantiated specialised agents (e.g., “Explainer”, “Critic”, “Ethics Monitor”, “Planner”) that coordinated via message passing and tool calls. IoT sensors provided contextual information (room occupancy, temperature, noise proxies) that could be consulted by agents when deciding on pacing and modality, consistent with the cyber-physical view in Section 2.3.
In addition to demographic information (age, gender, degree programme), we collected contextual variables such as course type (STEM vs. non-STEM), course level (introductory vs. advanced) and delivery mode (face-to-face vs. hybrid). These variables were later used as covariates to partially account for differences in baseline stress, workload and pedagogical culture across courses, acknowledging that unmeasured confounders remain.
The physical multi-agent station deployed in the university setting is shown in Figure 6.
Figure 9 depicts the high-level orchestration pipeline governing Phase 2.
Figure 9.
High-level orchestration pipeline for Phase 2. Students and lecturers interact with a multi-agent generative-AI layer, which also consults smart-campus IoT signals. All interactions and contexts are logged for subsequent analysis of the latent state dynamics and policy effects.
3.5. Generative-AI Platforms, Model Versions, and Access Dates
To improve transparency and replicability, we report the providers, model/version identifiers (as displayed by the platform at the time of use), access routes, and the period of use for each generative-AI system integrated into the Nested Learning ecosystem. These systems were used as instructional support tools (e.g., explanation, scaffolding, critique, and reflection prompts) and were not employed for automated grading or summative assessment decisions, consistent with the governance constraints described in Section 3.8.
Table 5 summarises the platforms used across Phase 1 (neuro-experimental calibration) and Phase 2 (field implementation). Whenever a platform exposed multiple selectable models over time, we documented the specific model selected for the study sessions and the access date range.
Table 5.
Generative-AI platforms, model versions, access routes, and usage period in the Nested Learning ecosystem.
Procedures and Micro-Cycle Design
Instructors attended a workshop introducing the Nested Learning paradigm and the orchestration interface. They learned to design micro-cycles of challenge–support–reflection aligned with their course content and to parameterise the autonomy and tone of AI agents (e.g., more Socratic vs. more directive support).
During teaching sessions, students interacted with generative-AI agents for tasks such as brainstorming, code generation, explanation of concepts and feedback on drafts. The orchestrator monitored interaction patterns, simple behavioural indicators (e.g., latency between prompts, rapid-fire requests, repeated queries) and IoT context to infer a coarse estimate of each learner’s state, in line with the measurement model in Equation (7). Based on this estimate and a configurable policy , the orchestrator adjusted suggested agent actions (e.g., switching from solution provision to metacognitive prompts, slowing down the pace, or encouraging a reflective pause).
Algorithm 2 provides a simplified pseudocode representation of the online orchestration loop for a single learner.
| Algorithm 2 Online orchestration loop for a single learner (Phase 2) |
|
The encoder in line 2 can be implemented using recurrent or attention-based models that integrate past and current observations. Although we do not optimise via reinforcement learning in this study, Algorithm 2 formalises the policy-level view discussed in Section 2.5 and provides a scaffold for future work.
At the end of the field implementation period, both students and lecturers completed the Nested Learning Experience Questionnaire (Section 3.6) and responded to open-ended questions about their experience with the ecosystem. These instruments provide proxies for the components of and for perceived properties of the policy (e.g., fairness, transparency, supportiveness).
3.6. Instruments
3.6.1. Nested Learning Experience Questionnaire
To capture participants’ perceptions of the ecosystem, we designed a Likert-type questionnaire with responses on a five-point scale (1 = strongly disagree, 5 = strongly agree). The instrument comprised 20 items grouped into four conceptual dimensions:
- (a)
- Perception of Nested Learning, assessing the extent to which learners felt enveloped in multi-layered cognitive and emotional support structures (e.g., “I feel accompanied by both teachers and AI tools when I get stuck”);
- (b)
- Interaction with Generative AI, focusing on perceived usefulness, clarity and trust in AI-mediated support (e.g., “The AI gives explanations that help me understand, not just the final answer”);
- (c)
- Perceived Neuroadaptive Adjustments, capturing how participants experienced changes in pacing, representation and difficulty in response to their state (e.g., “The system slows down or changes approach when I seem overloaded”);
- (d)
- Climate of Hope and Cognitive Safety, reflecting feelings of hope, non-punitive treatment of errors and protection of cognitive privacy (e.g., “I can make mistakes without feeling judged by the system”).
Each dimension contained five quantitative items. Items were formulated to align explicitly with the theoretical pillars described in Section 2 (Nested Learning, Pedagogy of Hope, multimodal neuroadaptation and governance/sustainability) [6,9,10,23,34]. The mapping between dimensions and theoretical constructs is summarised in Table 3. Negatively keyed items were reverse-coded before computing scale scores.
Internal consistency was assessed for each dimension using Cronbach’s and McDonald’s , yielding satisfactory reliability indices for the study sample (): Perception of Nested Learning (, ); Interaction with Generative AI (, ); Perceived Neuroadaptive Adjustments (, ); and Climate of Hope and Cognitive Safety (, ).
The questionnaire was conceived as a theory-driven, primarily confirmatory instrument; exploratory analyses are reported in Section 4 but do not override the original four-dimensional structure.
3.6.2. Qualitative Protocol
To complement quantitative data and preserve conceptual coherence, we developed a qualitative protocol consisting of 12 open-ended questions derived directly from the four quantitative dimensions (three questions per dimension). For example, the Nested Learning dimension included prompts such as “Describe a moment when you felt especially supported by the combination of teachers and AI tools”, whereas the cognitive-safety dimension included questions like “Have you ever felt that the system was invading your privacy? Why or why not?”.
This design ensured a one-to-one correspondence between quantitative and qualitative strands without the need for additional coding frameworks. Qualitative data were later analysed using a selective coding strategy, taking the four quantitative dimensions as central categories and identifying patterns, tensions and illustrative excerpts within each [12,33]. Coding was conducted by at least two researchers. An initial subset of responses (approximately 25%) was double-coded independently to refine the codebook and assess intercoder agreement (Cohen’s ), which is reported in Section 4. Discrepancies were resolved through discussion and, when necessary, consultation with a third reviewer. The remaining data were coded using the agreed scheme. This procedure reinforces the primarily confirmatory nature of the qualitative analysis, while still allowing for the identification of emergent subthemes within each dimension.
3.7. Data Analysis
3.7.1. Neuro-Experimental Data
For Phase 1, EEG data were processed as described above. Descriptive statistics were computed for P300 amplitude and latency across conditions and participants. To examine neuroadaptive sensitivity, we estimated Pearson correlations between P300 amplitude and continuous indices of pedagogical-event intensity, and fitted linear mixed-effects models with P300 amplitude as the dependent variable and event descriptors, condition indicators and participant-level random effects as predictors, following Equation (8) [14,16]. Logistic mixed models of the form in Equation (9) were used to model the probability of high-amplitude P300 responses as a function of event intensity and Nested Learning condition.
Model assumptions (normality of residuals, homoscedasticity, absence of influential outliers) were checked using standard diagnostic plots. Where necessary, robust standard errors were computed. Effect sizes (e.g., standardised coefficients, odds ratios) are reported in Section 4. Given the limited sample size and calibration focus, these analyses are interpreted as providing upper-bound estimates of sensitivity and as informing the design of future, larger-scale neuroadaptive studies.
3.7.2. Questionnaire and Interaction Data
For Phase 2, item-level responses were first inspected for missingness and distributional properties. Scale scores for each of the four dimensions were computed as the mean of their five constituent items. Descriptive statistics (means, standard deviations, skewness, kurtosis) were obtained for each dimension and for subgroups of interest (e.g., students vs. lecturers, programme type, course level).
Internal consistency of the scales was assessed using Cronbach’s and McDonald’s , with bootstrapped confidence intervals. Construct validity was examined through exploratory factor analysis (principal axis factoring with oblique rotation) followed by confirmatory factor analysis (CFA) in a separate split-half subsample to verify the four-factor structure and its alignment with the theoretical framework [13,23]. Global fit indices (CFI, TLI, RMSEA, SRMR) are reported in Section 4. Here again, analyses are primarily confirmatory, testing whether data are compatible with the a priori four-dimensional model derived from the theoretical framework, rather than searching for an entirely new latent structure.
To connect questionnaire scores with interaction traces, we computed correlations between dimension scores and behavioural indicators derived from the multi-agent station (e.g., number of AI interactions, diversity of agents used, frequency of reflective prompts, average conversation depth). Mixed-effects models were then estimated with dimension scores as outcomes and course-level variables (course type, level, delivery mode) and interaction indicators as fixed effects, plus random intercepts for course and instructor. These models provide an empirical bridge between the descriptive questionnaire data and the dynamical perspective articulated in Equation (3), with interaction indicators serving as proxies for support-quality components .
3.7.3. Qualitative Analysis and Triangulation
Qualitative responses were analysed using thematic coding with a deductive–inductive approach. A first coding cycle assigned excerpts to the four pre-defined dimensions (Nested Learning, interaction with generative AI, neuroadaptive adjustments, hope and cognitive safety). A second cycle identified subthemes within each dimension (e.g., transparency of AI, perceived over-reliance, feelings of being “accompanied” by the ecosystem, concerns about data use, experiences of empowerment or creative flow). As noted above, the main analytic stance was confirmatory, using the four dimensions as guiding categories; genuinely novel themes that did not fit the framework were noted and illustrated but not developed into a separate coding scheme, which we acknowledge as a methodological limitation.
Triangulation proceeded by constructing a composite dashboard that integrated key quantitative indicators (e.g., mean scores per dimension, distribution plots), neuroeducational markers from Phase 1 (e.g., P300 sensitivity indices) and qualitative themes. This dashboard enabled the inspection of convergent and divergent patterns (e.g., high Nested Learning scores combined with lingering concerns about privacy) and informed the interpretation of the dynamical model parameters at a conceptual level.
3.8. Ethical Considerations
All procedures complied with institutional and national guidelines on research ethics in human participants, as well as with current recommendations on AI and data protection in education [5,6,7,9,28,32]. Given that EEG signals can constitute special-category personal data when they enable inferences about health or neurocognitive states, we treated neurophysiological recordings and derived features under a GDPR Art. 9 compliance stance, adopting explicit consent as the primary lawful basis for processing and applying privacy-by-design measures throughout the pipeline.
For the neuro-experimental phase, participants provided written informed consent, including specific information about EEG recording, the nature of neuroeducational protocols and the right to withdraw at any time without penalty. Brain data were pseudonymised at the point of acquisition: each participant was assigned a random study code, and the re-identification key was stored separately from EEG data under restricted access. Raw EEG files and intermediate derivatives were stored encrypted at rest on access-controlled institutional drives; transfers to the analysis environment were encrypted in transit. Only de-identified, analysis-ready datasets (epochs/features) were used for modelling, and only aggregated results are reported in this article.
For the field implementation, both students and lecturers received extended information sheets describing the goals of the study, the role of generative-AI agents, the types of data collected (interaction logs, contextual signals, questionnaires), and the measures adopted to protect privacy and cognitive sovereignty. Data-minimisation principles were applied at all stages: interaction logs were limited to research-relevant metadata (timestamps, agent identifiers, coarse task tags) and did not include unnecessary personal content; IoT signals were used at contextual/aggregate resolution where possible. Importantly, the AI ecosystem did not perform automated grading decisions: participation had no impact on official assessment, and students could withdraw without academic consequences. The study protocol was reviewed and approved by the relevant institutional ethics committee (approval number and date to be specified in the final version).
To improve transparency and replicability of the data-protection workflow for neural data, Figure 10 summarises the processing and anonymisation steps from acquisition to reporting.
Figure 10.
Neural data processing and anonymisation workflow (GDPR Art. 9 compliance stance). The pipeline ensures data protection through three layers: Governance (consent and pseudonymisation), Infrastructure (encryption and access control), and Neuro-Analytics (artefact removal and aggregation).
In practice, privacy protections were implemented as: (i) strict data minimisation (only event markers and task-relevant logs), (ii) separation of identifiers from EEG/log files, (iii) role-based access control to raw EEG, (iv) encryption at rest and in transit, (v) short retention windows for raw neurodata with default aggregation, and (vi) opt-out without academic consequences. Importantly, the system was not used for individual neuro-profiling or automated grading decisions.
4. Results
Before presenting the neuro-experimental findings, Figure 11 summarises the Emotiv EPOC+ electrode montage and its correspondence with the main cortical lobes used in Phase 1.
Figure 11.
Emotiv EPOC+ electrode positions and their correspondence with cortical lobes.
Phase 1 was designed as a small-sample neuro-experimental calibration, not as a fully powered validation of a neuroadaptive system, and Phase 2 is an ecological field study without random assignment or tight experimental control. The analyses therefore probe the plausibility and boundaries of the Nested Learning model rather than offering a definitive or exhaustive empirical demonstration.
4.1. Phase 1: Neuroimaging Processing and Attentional Coupling
Interpretation boundary (Phase 1). Phase 1 is an exploratory feasibility calibration (not a fully powered validation). Its aim is to test whether low-cost EEG can yield interpretable, event-locked markers under a Nested Learning script; therefore, findings are reported as sensitivity evidence and should not be read as generalisable neuroeducational effects.
Low-cost mobile EEG introduces well-known limitations (lower spatial resolution, higher susceptibility to motion/EMG artefacts, and contact-quality variability). Accordingly, P300 is treated here as a coarse attentional proxy rather than a diagnostic or individual profiling signal, and it is interpreted only in triangulation with scripted events and behavioural/self-report evidence.
4.1.1. Data Quality, Artefacts and Retained Epochs
Across the 18 biomedical students, EEG signal quality remained generally stable under the preprocessing protocol reported in Section 3.3.4. After filtering, channel-level quality control and artefact handling, an average of 91.6% of epochs were retained as valid for ERP analysis. Data-quality indicators are summarised in Table 6, including channel-level artefacts, ICA applicability, the number of removed independent components (ICs), and epoch retention.
Table 6.
Phase 1 EEG data-quality and artefact-handling summary ().
These indices indicate that low-cost mobile EEG can support interpretable ERP extraction in this constrained context, while making explicit the boundary conditions: a minority of participants required a non-ICA pipeline, and retention depended on meeting minimum clean-epoch thresholds per event type.
4.1.2. ERP Topography and Frequency-Band Modulation
Topographical inspection of averaged ERPs revealed a pattern compatible with centro-parietal P300 generators, with maximal amplitudes over centro-parietal sites and a gradual decrease towards frontal and occipital electrodes, consistent with attention-related P300 distributions in educational tasks [14,16,17]. Exploratory frequency-band descriptors suggested an increase in frontal theta and a modulation of parietal alpha during Nested Learning segments, compatible with phases of heightened cognitive control followed by stabilisation of the task set. These band-level observations are interpreted cautiously, as they were not the primary endpoint of Phase 1.
4.1.3. P300 Contrasts and Mixed-Effects Sensitivity Models
To provide an interpretable anchor beyond schematic visuals, Table 7 reports descriptive contrasts between baseline and Nested Learning segments in the P300 window (250–400 ms), focusing on posterior channels corresponding to Pz in the Emotiv montage.
Table 7.
Descriptive P300 contrasts between baseline and Nested Learning segments (Phase 1; posterior/Pz proxy).
Figure 12 provides a schematic summary of the ERP dynamics, highlighting the contrast between baseline and Nested Learning segments.
Figure 12.
Schematic representation of P300 dynamics in Phase 1. Nested Learning segments show higher parietal P300 amplitudes than baseline segments in the 250–400 ms window, consistent with increased attentional engagement and neuro-adaptive sensitivity. Curves are illustrative rather than raw waveforms.
Linear mixed-effects models with P300 amplitude as the outcome and pedagogical-event descriptors as predictors (Section 3.3) showed that higher event intensity and Nested Learning segments were associated with increased P300 amplitude, with participant-level random intercepts. Logistic mixed models for the probability of high-amplitude P300 responses yielded convergent patterns, supporting the modelling assumptions in Equations (8) and (9). Table 8 summarises the fixed-effect estimates.
Table 8.
Mixed-effects models of P300 sensitivity (Phase 1).
Given the modest sample size and feasibility-oriented nature of Phase 1, these results are interpreted as sensitivity checks and proof-of-concept evidence that the pipeline can track attentional coupling between pedagogical micro-events and cortical responses. They provide an empirical anchor for the engagement-related component in Equation (3), but do not exhaustively validate the full state-space formulation.
4.2. Phase 2: Impact on Engagement and Self-Regulation
4.2.1. Descriptive Patterns, Reliability and Subgroup Analysis
In the large-scale field implementation (), questionnaire responses indicated generally positive perceptions across all four dimensions and the two outcome scales. Table 9 summarises the descriptive statistics, distributional properties and reliability indices for each construct.
Table 9.
Descriptive statistics, distributional properties and reliability indices for Nested Learning dimensions and outcomes ().
As shown in Table 9, all dimensions exhibited means well above the scale midpoint (3.0), ranging from 3.88 (Neuroadaptive Adjustments) to 4.25 (Climate of Hope). The indices of skewness were consistently negative (ranging from to ), confirming a left-skewed distribution where the majority of participants reported high levels of perceived support and safety. Kurtosis values remained within the acceptable range () for normal theory-based estimation methods, supporting the use of parametric analyses. Reliability coefficients ( and ) exceeded 0.80 for all scales, consistent with recommendations to report alongside for Likert-type measures [43].
Regarding the subgroups of interest specified in the methodology, independent samples t-tests were conducted to compare Students () and Lecturers (). To control family-wise error across multiple subgroup comparisons, p-values were Holm-adjusted. Results revealed a high degree of convergence in perceptions (adjusted for NL, SAF and ENG), suggesting that the ecosystem was experienced similarly by both learners and educators. A statistically significant, small difference was observed in Interaction with Generative AI, where students reported slightly higher usage and perceived utility () compared to lecturers (; , Holm-adjusted , ). No significant differences were found based on degree programme (STEM vs. non-STEM) or course level.
Reflective prompts and metacognitive interventions were frequently triggered in segments where the orchestrator inferred high cognitive load or decreasing engagement, consistent with the behavioural logs. These descriptive patterns provide the empirical foundation for the correlational and regression analyses that follow.
4.2.2. Construct Validity: Factor Structure
To examine construct validity, the total sample () was randomly split into two independent subsamples ( for EFA; for CFA). EFA (principal axis factoring, direct oblimin) supported a four-factor solution (KMO = 0.89; Bartlett , ) explaining 68.4% of total variance, with primary loadings on their intended dimensions and no problematic cross-loadings. CFA on the second split confirmed excellent global fit (Table 10). To ensure interpretability across roles, an additional multi-group CFA (students vs. lecturers) supported at least metric equivalence (configural and metric models showed acceptable fit), justifying subgroup comparisons at the scale level. All items loaded significantly (>0.50) on their respective theoretical dimensions (Nested Learning, Interaction with AI, Neuroadaptive Adjustments, and Cognitive Safety), with no substantial cross-loadings.
Table 10.
Global fit indices for the four-factor Confirmatory Factor Analysis (CFA) model ().
Second, a Confirmatory Factor Analysis (CFA) was performed on the second subsample to verify the four-factor structure. The model specification allowed latent factors to correlate. As shown in Table 10, the Global Fit Indices demonstrated an excellent fit to the data, meeting standard thresholds for adequacy.
The combination of EFA and CFA results confirms that the instrument possesses a robust four-dimensional structure consistent with the theoretical framework proposed in Section 2, justifying the use of the four composite scores in subsequent analyses.
4.2.3. Correlations Between Nested Learning, AI Interaction and Outcomes
Pearson correlations among the five composite scales were positive and moderate to strong (Table 11). To reduce the risk of inflated Type-I error due to multiple correlation tests, we additionally verified significance under FDR control; all reported associations remained significant (). Engagement and Self-Regulation were strongly correlated (), consistent with the view that sustained involvement and metacognitive control are tightly linked in Nested Learning contexts [10,23]. From the dynamical perspective of Equation (3), these correlations are compatible with the interpretation that higher perceived Nested Learning and neuroadaptive adjustments are associated with higher outcome components and ; however, the cross-sectional design precludes causal claims.
Table 11.
Correlation matrix between Nested Learning (NL), Interaction with Generative AI (INT), Perceived Neuroadaptive Adjustments (NA), Engagement (ENG) and Self-Regulation (SRL).
Nested Learning showed the strongest associations with Perceived Neuroadaptive Adjustments () and Engagement (), while Interaction with Generative AI exhibited moderate correlations with the other scales (r between 0.41 and 0.54). Engagement and Self-Regulation were strongly correlated (), consistent with the view that sustained involvement and metacognitive control are tightly linked in Nested Learning contexts [10,23].
From the dynamical perspective of Equation (3), these correlations are compatible with the interpretation that higher perceived Nested Learning and neuroadaptive adjustments are associated with higher levels of the outcome components (engagement) and (self-regulation). However, the cross-sectional nature of the questionnaire data prevents strong causal claims.
4.2.4. Predictive Models for Engagement and Self-Regulation
To examine the joint contribution of Nested Learning and Perceived Neuroadaptive Adjustments, we fitted multiple linear regression models with Engagement and Self-Regulation as dependent variables (Table 12). Because participants were nested within courses, we also estimated multilevel models with random intercepts for course. Fixed-effect estimates were materially unchanged, and intraclass correlations (ICCs) were modest, suggesting that the primary associations are not artefacts of course-level clustering.
Table 12.
Multiple linear regression models for Engagement (ENG) and Self-Regulation (SRL) with Nested Learning (NL) and Perceived Neuroadaptive Adjustments (NA) as predictors.
Nested Learning emerged as the strongest predictor in both models ( for Engagement; for Self-Regulation), with Perceived Neuroadaptive Adjustments also contributing substantially ( and , respectively). The models explain 39% and 34% of the variance in Engagement and Self-Regulation, respectively. Figure 13 synthesises these relationships as a path diagram, emphasising that Nested Learning and neuroadaptive adjustments jointly relate to engagement- and self-regulation-related components of the latent state vector .
Figure 13.
Path representation of regression results. Nested Learning (NL) and Perceived Neuroadaptive Adjustments (NA) jointly predict Engagement (ENG) and Self-Regulation (SRL), with standardised coefficients shown on each path (all ). Arrows represent statistical associations, not causal effects.
Figure 13 synthesises these relationships as a path diagram, emphasising that Nested Learning and neuroadaptive adjustments jointly drive engagement- and self-regulation-related components of the latent state vector .
From the standpoint of the dynamical system in Equation (3), these findings are consistent with (but do not prove) the interpretation that Nested Learning and neuroadaptive quality modulate the effective growth parameters and for engagement and self-regulation, increasing the probability that learners move towards desirable regions of the state space without destabilising the process.
ENG and SRL are treated as proximal sustainability indicators because sustained engagement and self-regulatory capacity are consistently linked to persistence and reduced disengagement risk in higher education; SAF is treated as a protective condition against anxiety-driven avoidance and burnout. However, we do not claim long-term sustainability effects in this study because dropout, equity gaps, and workload were not measured longitudinally.
4.3. Qualitative Results: Four Thematic Families of Nested Learning
The thematic analysis of the 12 open-ended questions (Section 3.6) yielded four main families that mirror the quantitative dimensions: (1) Task Engagement, (2) Academic Self-Regulation, (3) Perceived Neuroadaptive Adjustments and (4) Emotional Climate and Cognitive Safety. Each family contained several hundred coded excerpts, reflecting rich and nuanced student narratives.
4.3.1. Family 1: Task Engagement
The first family (Task Engagement) comprised 512 coded excerpts, dominated by codes such as sustained attention, immersion, sense of progress, persistence and avoidance of dropout. Students frequently described uninterrupted focus, a feeling that time “passed quickly” and a sense of advancing through clearly structured stages. Many accounts emphasised that AI-mediated scaffolding, combined with the teacher’s presence, helped them remain engaged during complex segments rather than giving up prematurely. These narratives align with the strong quantitative correlations between Nested Learning, Perceived Neuroadaptive Adjustments and Engagement (Table 11).
4.3.2. Family 2: Academic Self-Regulation
The second family (Academic Self-Regulation) involved 389 coded excerpts with codes such as planning, monitoring learning, time management, strategy adjustment and autonomous help-seeking. Participants described being able to detect when they were “getting lost”, adjust their approach and use AI agents proactively for clarification instead of waiting passively for the lecturer. Immediate feedback and the possibility of iterating with generative AI allowed them to correct misunderstandings earlier in the process, which resonates with the predictive role of Nested Learning and neuroadaptive adjustments in the Self-Regulation model (Table 12).
4.3.3. Family 3: Perceived Neuroadaptive Adjustments
The third family (Perceived Neuroadaptive Adjustments) contained 301 excerpts and included codes such as personalisation, pacing adjustment, level adaptation, progressive guidance and perceived adaptation. A recurrent theme was the sensation that the system “adapted to me” rather than enforcing a fixed script. Students noted that, when they were stuck, the AI changed the type of example or explanation, enabling progress without feeling overwhelmed. Qualitative co-occurrence patterns between personalisation codes and references to feeling supported mirror the statistical contribution of neuroadaptive adjustments in predicting Engagement and Self-Regulation ( and ).
4.3.4. Family 4: Emotional Climate and Cognitive Safety
The fourth family (Emotional Climate and Cognitive Safety) included 224 excerpts and was characterised by codes such as reduced anxiety, sense of support, confidence to make mistakes and renewed motivation. Students reported feeling emotionally safe, able to experiment and fail without fear of judgement, and consistently accompanied by some form of support (human and/or AI). These narratives align with the role of the cognitive-safety component in the dynamical model and with the ethical and governance principles in Section 3.8: Nested Learning is experienced not only as a cognitive scaffold but as an affective and ethical envelope.
4.3.5. Cross-Family Synthesis
Across the four families, a convergent pattern emerged:
- Engagement arises from the clarity of the process and the immersive structure of Nested Learning;
- Self-regulation is strengthened by immediate feedback and adaptive structure;
- Neuroadaptive adjustments are perceived as genuine personalisation rather than generic automation;
- A safe emotional climate acts as a key mediator of attentional stability and persistence.
Figure 14 summarises these relationships as a qualitative map around the Nested Learning ecosystem.
Figure 14.
Qualitative map of the four thematic families surrounding the Nested Learning ecosystem. Each family feeds into and is reinforced by the ecosystem, highlighting the interdependence between engagement, self-regulation, neuroadaptive personalisation and emotional safety.
This convergence between qualitative themes, questionnaire scores and neuroeducational markers supports the interpretation of Nested Learning as a neuro-adaptive, agent-mediated cycle that shapes the trajectory of the multidimensional learner state over time, while acknowledging that these inferences are based on observational data.
4.4. Technical Performance Versus Ethical Constraints
A comparative analysis of the six generative-AI platforms (ChatGPT, Gemini, Claude, Copilot, DeepSeek and GPT-o1) within the multi-agent station revealed differentiated profiles in terms of responsiveness, controllability and perceived transparency. Some agents were preferred for rapid draft/code generation, whereas others were favoured for explanatory style, uncertainty signalling, or perceived alignment with ethical constraints.
From a governance perspective, participants and instructors highlighted a recurring tension between deep personalisation—enabled by fine-grained tracking of learner states and interactions—and concerns about privacy, over-surveillance and potential misuse of neurocognitive and behavioural data. These concerns echo the constraints discussed in Section 3.8 and frame the practical challenge of implementing under data-minimisation, transparency and cognitive-sovereignty requirements [6,9].
Phase 1 suggests that Nested Learning micro-events can be tracked through robust P300 markers using affordable EEG; Phase 2 shows that Nested Learning and neuroadaptive adjustments are strongly associated with engagement and self-regulation, both quantitatively and qualitatively; and the technical–ethical analysis underscores that sustaining such an ecosystem in higher education requires careful balancing of technical performance and protection of learners’ rights.
4.5. Empirical Convergence Patterns in the Latent Learner State
Section 2.5 formalised the Nested Learning ecosystem as a discrete-time dynamical system in which each learner is represented by a latent state vector. For the purposes of this section, we focus on the four components most directly informed by questionnaire and qualitative data,
encoding, respectively, engagement, self-regulation, cognitive safety and hope-related climate, while the performance component is treated separately. Component-wise updates were described by Equation (3). Empirically, we approximate and from the Engagement and Self-Regulation scales, rescaled to , while and are informed by items on perceived cognitive safety and hope-related climate. The predictors in Table 12—Nested Learning (NL) and Perceived Neuroadaptive Adjustments (NA)—can be interpreted as coarse-grained proxies of the control term , since they aggregate perceived clarity of structure, adaptivity and contextual sensitivity of the ecosystem.
Under this mapping, the regression results imply that the expected increment in the engagement- and self-regulation-related components is positive when NL and NA are above minimal levels, and that increments should diminish as states approach a ceiling (consistent with logistic-type updates). Importantly, because Phase 2 is cross-sectional, these convergence claims are presented as model-supporting interpretations rather than direct longitudinal evidence.
Phase 1 provides a complementary view for attentional coupling: P300 dynamics indicate that salient challenge–support–reflection micro-events reliably modulate attention-related ERP signatures, supporting the plausibility of an engagement-related state component monitored through neuroadaptive markers.
Figure 15 provides an illustrative interpretation of the logistic-type convergence implied by Equation (3), highlighting diminishing increments as approaches its ceiling.
Figure 15.
Illustrative convergence trajectories for the engagement component under a Nested Learning policy. Both learners move from low to high engagement, but with different effective learning-speed parameters . The empirical results—high engagement, strong self-regulation and stabilised neuroeducational markers—are consistent with trajectories that approach a high-value equilibrium with diminishing increments .
Although Phase 2 relies on post-implementation questionnaire measures rather than repeated within-person trajectories, the combination of (i) robust associations between NL/NA and engagement/self-regulation, (ii) strong convergent qualitative narratives, and (iii) sensitivity-calibrated neuroeducational markers in Phase 1 is consistent with the view that the ecosystem supports positive increments that gradually shrink as learners approach desirable regions of the state space. This consistency should be understood as model-supporting rather than as a formal convergence proof.
Empirical Instantiation
In this study, the dynamical variables are not observed as dense individual time series. We therefore instantiate the model at a coarse-grained level: ENG and SRL questionnaire composites are rescaled to as proxies for and , while SAF items inform . Perceived NL and NA act as proxies for the control term because they aggregate perceived structure, pacing and adaptivity of the orchestration policy.
Under this mapping, regression coefficients should be interpreted as associational evidence that higher perceived orchestration quality (NL/NA) is compatible with positive average increments in engagement/self-regulation components, not as identification of individual parameters nor as proof of stability.
4.6. From Local Increments to Sustainable Trajectories
The dynamical framing also clarifies the sustainability implications of Nested Learning. At each step, the policy selects agent actions and neuroadaptive adjustments that are expected to produce increments
in directions aligned with the pedagogical goals of the ecosystem: increased engagement (), stronger self-regulation (), higher cognitive safety () and a more hopeful, resilient outlook (). Phase 1 suggests that this can be done without pushing the system into pathological regimes of over-arousal or stress, as indicated by the balanced profile of EEG bands and neuroeducational markers described in Section 4.1. Phase 2 demonstrates that the same policy is associated with high levels of perceived clarity, adaptivity and emotional safety.
Within this perspective, sustainability can be interpreted as the existence of regions of the state space where:
- (a)
- the expected increments are small but non-negative for desirable components (no rapid decay of engagement or self-regulation);
- (b)
- fluctuations remain bounded, avoiding oscillatory or unstable trajectories;
- (c)
- ethical and governance constraints on data usage and cognitive sovereignty are enforced at the policy level, constraining the admissible control signals .
The empirical configuration observed in this study—high engagement and self-regulation, low cognitive stress, strong perceptions of personalisation and safety, and explicit concerns about privacy that feed back into governance design—is compatible with such a “sustainable region”. In that region, the nested ecosystem acts as a regulator that gently pushes trajectories back towards pedagogically desirable zones when disturbances (e.g., overload, anxiety, loss of motivation) displace learners from them, rather than as an engine that maximises short-term performance at the cost of long-term wellbeing.
This interpretation reinforces the central claim of the paper: Nested Learning is not only a technical architecture but a policy-level design for shaping the temporal evolution of learner states in ways that are mathematically tractable, empirically grounded and aligned with the human-centric aspirations of Industry 5.0 and a Pedagogy of Hope.
5. Discussion
This section interprets the empirical results through the lens of the Nested Learning framework and the underlying dynamical model, and discusses implications for sustainable higher education. Consistent with the mixed-methods and feasibility-oriented nature of the study, our aim is not to claim definitive validation, but to examine the extent to which observed patterns are compatible with the proposed conceptual and mathematical structure, and to specify where uncertainty and boundary conditions remain. We organise the discussion around five axes: (i) the viability and limits of low-cost neuro-adaptive monitoring, (ii) the role of Nested Learning and perceived neuroadaptive adjustments in relation to engagement and self-regulation, (iii) what the dynamical perspective adds beyond correlational accounts, (iv) robustness and alternative explanations, and (v) ethical/governance constraints that bound acceptable trajectories of learner states.
Operationalisation of sustainability. We use sustainability in higher education in an operational sense: (i) persistence-related proximal indicators (engagement, self-regulation), (ii) protective conditions for wellbeing (cognitive safety), (iii) equity and accessibility considerations, and (iv) feasibility for instructors (governed orchestration and workload). In this manuscript we measure proximal indicators and governance tensions; downstream outcomes (e.g., dropout reduction, equity gaps, instructor time-on-task) are proposed for future longitudinal evaluation.
What is supported by the present data. Phase 1 supports feasibility of event-locked attentional monitoring under low-cost EEG in a scripted setting (exploratory). Phase 2 supports robust associations between perceived Nested Learning/neuroadaptive adjustments and engagement/self-regulation, complemented by convergent qualitative themes.
What remains conceptual or future-facing.The dynamical framing specifies a policy-level design language and testable hypotheses about trajectories and stability; however, it is not fully identified from the present dataset and should be treated as a generative scaffold for longitudinal and comparative studies.
5.1. Neuro-Adaptive Viability in Authentic Educational Contexts
A central question was whether a neuro-adaptive ecosystem can be instantiated with affordable hardware and realistic constraints, without relying on laboratory-only paradigms. Within the limits of a small and homogeneous sample, Phase 1 suggests feasibility: using a low-cost 14-channel mobile EEG device, we obtained stable recordings with more than 90% retained epochs after artefact handling, and P300 signatures that differentiated Nested Learning segments from baseline activity in this specific group.
The observed P300 topography and timing are compatible with classical accounts of attention and context updating [14,16,17]. Importantly, these signatures emerged in tasks mediated by ChatGPT and embedded in a pedagogical micro-cycle of challenge–scaffolding–reflection, rather than in simplified oddball-like paradigms. This supports, at a feasibility level, the idea that neuroeducational markers can be elicited under comparatively ecologically valid conditions, aligning with the broader ambition of neuroeducation to bridge laboratory findings and classroom practice [10,13].
At the same time, low-cost EEG in classroom-adjacent settings introduces non-trivial risks: motion and muscle artefacts, variable contact quality, and interpretability gaps if signals are not triangulated with behavioural traces and self-report. For this reason, our Phase 1 pipeline should be interpreted as sensitivity calibration for attentional coupling, not as a general-purpose neurodiagnostic mechanism. This distinction is central for sustainability: ecosystems that depend on fragile or opaque neuro-inferences may be technically impressive but socially brittle. The sustainable strategy is a “minimal sufficient sensing” posture, where neuro-signals are optional, interpretable, and embedded in a broader multimodal evidence base rather than treated as privileged truth.
From the standpoint of the measurement function in Equation (7), P300 and related neuroeducational indices act as partial readouts of the engagement component . The fact that attentional markers remained in a functional range during Nested Learning micro-cycles is compatible with the idea that the policy steers learners away from both under-stimulation (boredom) and over-stimulation (overload). However, the modest sample size, the absence of an alternative scripted condition in Phase 1, and plausible novelty effects constrain inference. Replication across disciplines, tasks, and cohorts is required before claiming general neuro-adaptive reliability.
5.2. Nested Learning, Engagement and Self-Regulation
Phase 2 indicates that perceived Nested Learning and Perceived Neuroadaptive Adjustments are strongly associated with Engagement and Self-Regulation. The correlation structure (Table 11) and regression paths (Figure 13) suggest that participants who experienced higher levels of coherent nested support (multi-layered human–AI scaffolding) and adaptation (pacing, representation, difficulty) reported higher engagement and stronger self-regulatory practices. This quantitative pattern is reinforced by the four qualitative thematic families (Figure 14), which emphasise immersion, sense of progress, planning, monitoring and strategic help-seeking.
These findings align with SRL and affective accounts of learning that stress the role of timely feedback, structured support and emotionally safe environments in sustaining engagement and metacognitive competence [10,11,23]. The present study adds a systems layer: these processes appear distributed across a socio-technical network in which educators, peers, multi-agent generative AI, and context signals jointly shape the learner experience [46].
A key interpretive nuance is that engagement and self-regulation are context-sensitive constructs. Disciplinary norms, task epistemologies and professional identity shape what is experienced as “good support” versus “over-scaffolding”. Although we did not observe strong STEM/non-STEM differences in this implementation, Phase 1 used biomedical students and Phase 2 occurred within a particular institutional culture. This implies that the same orchestration policy may yield different trajectories across domains (e.g., code-oriented tasks vs. interpretive writing), which future stratified studies should test explicitly.
In this sense, Nested Learning can be read as a Pedagogy-of-Hope operationalisation for AI-rich contexts [34]. Rather than using AI primarily to accelerate grade-centric production, the ecosystem foregrounds process visibility, cognitive safety and reflexive dialogue, aiming to preserve learner agency. The association between Nested Learning, neuroadaptive adjustments and self-regulation is consistent with the claim that generative AI, when deliberately framed and governed, can support rather than erode agency [3,5]. Nevertheless, the observational design, the lack of a non-nested comparison condition, and potential confounders (e.g., instructor enthusiasm, AI novelty, local culture) mean alternative explanations remain plausible.
5.3. Dynamical Interpretation: From Correlations to Trajectories
Section 2.5 conceptualised Nested Learning as a discrete-time process in which each learner is represented by a state vector (performance, engagement, self-regulation, cognitive safety). The present data do not provide dense individual time series, but they do support reasoning about expected increments
and the qualitative shape of trajectories under a policy .
The combination of (i) robust positive associations between perceived nested support/neuroadaptation and engagement/self-regulation, (ii) qualitative evidence of planning and monitoring practices, and (iii) attentional coupling in Phase 1 is compatible with a regime where and are on average positive but diminishing as learners approach higher levels—a pattern consistent with the logistic-type structure in Equation (3). In that equation, increments scale with the gap-to-target and a control term encoding the alignment and quality of agent actions and contextual orchestration.
A key advantage of this framing is that it re-centres policy design. The goal is not only to predict what learners will do next, but to ask what sequences of actions help them remain within sustainable regions of the state space—high engagement and self-regulation without compromising cognitive safety. This is conceptually distinct from purely predictive models such as classical knowledge tracing: it treats feedback timing, pacing, and representational choices as explicit control signals whose stability and ethical admissibility matter.
At the same time, the current dataset does not permit formal identification of individual parameters or stability analysis. The dynamical equations should therefore be read as a generative scaffold that organises hypotheses and design choices, rather than as a fully estimated mechanistic model. Future work should collect repeated within-learner measures (e.g., task-level trajectories, ecological momentary assessments, or week-by-week micro-surveys) and integrate them with interaction logs to estimate increments directly and test convergence claims.
5.4. Robustness and Alternative Explanations
Because Phase 2 is ecological and non-randomised, robustness checks and alternative explanations are essential. Several mechanisms could inflate associations: self-selection into participation, social desirability in self-report, instructor enthusiasm effects, and common-method variance given that multiple constructs were measured via the same questionnaire instrument.
We addressed these concerns partially through design and analysis choices. First, construct validity was supported by a split-sample EFA/CFA and excellent model fit (Table 10), reducing the likelihood that results are artefacts of ill-posed measurement models. Second, subgroup comparisons suggested substantial convergence between students and lecturers on most dimensions, with only small differences in Interaction with Generative AI, consistent with role expectations rather than wholesale perceptual divergence. Third, models were checked under course-level clustering (random intercepts), and the primary fixed-effect patterns were stable, suggesting that the results are not driven solely by a small number of courses or instructors.
However, these checks do not eliminate endogeneity. In particular, it is plausible that instructors who embraced the ecosystem also implemented more supportive pedagogy in general, or that participants with higher intrinsic motivation engaged more deeply with both AI agents and reflective prompts. Therefore, the most defensible interpretation is associative: Nested Learning perceptions co-vary with engagement and self-regulation in this implementation, consistent with the framework, but not establishing causal effects.
Methodologically, the next step is a comparative design that preserves ecological plausibility: stepped-wedge rollouts, matched-course comparisons, or cluster-randomised micro-interventions where the orchestration policy is varied within safe bounds. These designs would allow stronger tests of whether changing policy parameters produces predicted shifts in increments .
5.5. Design Principles for Sustainable Nested Learning Ecosystems
Synthesising Phase 1 (neuro-sensitivity calibration), Phase 2 (field perceptions and associations), and qualitative themes suggests provisional design principles for sustainable Nested Learning deployments:
- (a)
- Layered orchestration over single-tool adoption. Positive experiences are more likely when learners perceive a coherent envelope of support (teachers, agents, peers, context) rather than isolated chatbot usage.
- (b)
- Transparent, trace-based feedback. Making planning traces, evidence citations, revision steps and adaptation triggers visible supports SRL and reduces dependence on opaque AI outputs.
- (c)
- Fail-soft neuroadaptation. Neuro-signals should calibrate sensitivity and trigger optional adaptations; the system must degrade gracefully to behavioural/self-report signals when EEG is noisy or absent.
- (d)
- Hope-centred error culture. Prompting and assessment formats should normalise uncertainty and iterative refinement, reframing errors as informative rather than punitive [34].
- (e)
- Human-governed orchestration. Teachers must retain meaningful control over agent roles, thresholds and intervention styles; governance is part of the pedagogy, not an external constraint [6,9].
- (f)
- Drift-aware reproducibility. Because LLMs evolve, sustainable deployments should log model versions, policy configurations and prompt templates, and maintain lightweight evaluation harnesses for performance/safety drift monitoring.
- (g)
- Equity-by-design. The policy should explicitly monitor differential trajectories across subgroups, not only average gains, to avoid reinforcement of existing inequities through uneven support quality.
These principles are context-sensitive heuristics rather than universal rules, but they translate the mathematical framing (control signals, stability corridors, bounded trajectories) into actionable institutional choices.
5.6. Ethical and Governance Implications
The findings foreground a persistent tension between personalisation and privacy. Fine-grained monitoring of engagement and SRL can enable timely support, yet participants expressed concerns about over-surveillance, data misuse and loss of cognitive sovereignty, particularly when neurodata are involved. In the dynamical framing, this is naturally expressed as a constraint on admissible controls : not all interventions that may improve short-term increments are ethically acceptable.
Accordingly, deployments should embed privacy-by-design and data minimisation at the architectural level, treating governance as a first-class subsystem rather than a post-hoc add-on [6,9,48,49]. Practically, this implies: explicit consent granularity (what is collected, why, and for how long), transparent explanations of adaptation triggers, separation of educational support from grading consequences, and auditable logs that record which policy actions occurred without exposing unnecessary sensitive content.
Finally, governance should be communicated in ways that align perceived and actual safeguards: trust depends not only on compliance, but on intelligibility and participatory legitimacy. In Nested Learning terms, cognitive safety is not merely a state component; it is also a property of institutional practice.
5.7. Limitations and Directions for Future Research
Several limitations qualify interpretation and motivate future work.
First, Phase 1 involved a small, homogeneous sample; while results are compatible with prior P300 literature, generalisation across disciplines, age groups and cultures is uncertain. Replications with larger, diverse cohorts and alternative pedagogical scripts are needed to establish boundary conditions for low-cost neuro-adaptive monitoring.
Second, Phase 2 relied primarily on self-report and logs at limited time points. We did not observe repeated within-person trajectories of across many tasks, nor include a non-nested comparison condition. Longitudinal designs with task-level repeated measures are required to estimate increments directly and to identify individual parameters .
Third, the control policy was rule-based and teacher-configured; we did not optimise it algorithmically. While this supports interpretability and oversight, future work could examine constrained optimisation under strict safety envelopes, provided it remains auditable and educator-legible [3,6].
Fourth, the mapping from questionnaire scales to latent state components is necessarily coarse. Engagement, SRL and cognitive safety are complex constructs not exhaustively captured by Likert items. Incorporating richer behavioural indicators (revision patterns, persistence, prompt diversity, evidence-seeking) and linking them to outcomes would strengthen state estimation and reduce common-method bias.
Fifth, model drift is an under-appreciated threat to replicability: platform updates may change agent behaviour over time. Future studies should report model/version metadata, prompt templates and policy configurations, and maintain benchmark tasks to support drift-aware comparisons across cohorts.
Despite these constraints, the convergence of neuroexperimental sensitivity calibration, large-scale field perceptions, and a mathematically grounded framing suggests that Nested Learning is a promising direction for designing AI-mediated, neuro-adaptive and sustainable higher-education ecosystems. Future work should expand the empirical base, strengthen causal identification, and co-design governance with students and educators to ensure alignment with human-centred values and the long-term goals of sustainable education.
6. Conclusions
This article has outlined Nested Learning as a policy-aware working model for a neuro-adaptive, agent-mediated ecosystem in sustainable higher education. Building on the convergence of generative AI, neuroeducation and smart-campus infrastructures, we described (i) a multi-layer architecture (Figure 2), (ii) a theory-aligned measurement logic spanning behavioural, self-report and optional neuroeducational signals, and (iii) a dynamical framing of learner states in which assessment, feedback and support operate as policy-level design variables rather than static procedures. Our contribution is therefore primarily organising and design-oriented: we show how a mathematically explicit and ethically constrained perspective can structure decisions in AI-rich environments that aim to sustain engagement, self-regulation and cognitive safety over time, consistent with human-centric orientations associated with Industry 5.0 [8,9].
Empirically, the study combined (i) a neuro-experimental calibration () and (ii) an ecological field implementation (). Within the limits of a small and homogeneous Phase 1 sample, low-cost mobile EEG captured interpretable P300 dynamics and a balanced neuroeducational profile during ChatGPT-mediated tasks, supporting the feasibility of event-locked neuro-adaptive pipelines in ecologically plausible settings. Phase 2 indicates that perceived Nested Learning and perceived neuroadaptive adjustments are moderately to strongly associated with engagement and self-regulation, both quantitatively (correlations and regression models) and qualitatively (four thematic families centred on immersion, planning, personalisation and emotional safety). Interpreted through the dynamical lens, these patterns are compatible with trajectories in which relevant components of the learner state vector move towards desirable regions with diminishing increments . However, the present evidence does not support causal attribution, formal estimation of individual dynamical parameters, or rigorous stability proofs; the model should be read as a generative scaffold that organises hypotheses and bounded design choices.
From a sustainability perspective, three provisional conclusions follow. First, human-centred AI in higher education appears to require multi-layer orchestration: the most positive experiences arise when teachers, AI agents, peers and physical context are perceived as a coherent envelope of support rather than as isolated tools. Second, cognitive safety and a Pedagogy of Hope are explicit design targets, not by-products: normalising productive error, foregrounding process visibility and regulating arousal within a safe corridor emerge as central to long-term wellbeing and resilience, particularly for students at risk of disengagement or burnout [12,34]. Third, governance is integral to the technical architecture: privacy-by-design, data minimisation, transparency about adaptation triggers, and meaningful human oversight over agent policies are necessary conditions for aligning neuro-adaptive capabilities with ethical and regulatory expectations [6,9].
The framework suggests practical implications for universities advancing the Sustainable Development Goals (especially SDG 4 on quality education and SDG 3 on health and wellbeing). Institutions can: (i) pilot multi-agent, generative-AI stations that prioritise process, justification and reflection rather than answer delivery alone; (ii) cautiously integrate lightweight neuroeducational sensing as an optional and fail-soft layer to monitor attentional and emotional balance at aggregate/cohort level (avoiding individualised neuro-profiling by default); and (iii) adopt trace-based assessment formats that value planning, testing discipline and evidence use alongside product quality. These steps point beyond efficiency-driven narratives towards a model of higher education that explicitly cares for learners’ cognitive and emotional trajectories while remaining sensitive to privacy and cognitive sovereignty.
To visually anchor the attentional coupling assumed by the framework, Figure 16 provides an illustrative neuroimaging-style view of real-time neuroelectric dynamics associated with cognitive nesting, conveying how pedagogical micro-events can be related to temporally evolving cortical activity without implying clinical-grade localisation or diagnostic inference.
Figure 16.
Illustrative neuroimaging-style view of real-time neuroelectric dynamics associated with cognitive nesting.
At the same time, the study has clear limitations in sample diversity, longitudinal depth, and causal identification, as discussed in Section 5. Future research should therefore: (i) replicate the approach across disciplines, countries and institutional cultures; (ii) collect longitudinal task-level trajectories to estimate increments directly and to empirically characterise “sustainable regions” of the state space under different policies; (iii) compare alternative orchestration policies using ecologically plausible quasi-experimental designs (e.g., stepped-wedge or matched-course rollouts); and (iv) co-design governance protocols with students, teachers and policymakers so that evolving AI capabilities remain aligned with human values and rights.
In conclusion, Nested Learning is best understood as a governance-aware blueprint for turning AI and IoT infrastructures into engines of more sustainable education rather than sources of additional pressure or inequality. By treating learner states as trajectories to be carefully guided—not merely as scores to be extracted—higher education can begin to harness generative AI in ways that pursue technological sophistication and human flourishing together, under explicit ethical constraints and institutional oversight.
Accordingly, claims in this paper are feasibility- and compatibility-oriented; effectiveness, stability and long-term sustainability impacts require longitudinal designs with downstream indicators (completion, dropout intention, equity gaps and instructor workload).
Author Contributions
Conceptualization, R.J. and A.H.-F.; methodology, C.B.C.; software and data analysis, R.J. and C.B.C.; theoretical framework and literature review, A.H.-F. and D.M.; writing—original draft, R.J. and A.H.-F.; writing—review and editing, C.B.C. and D.M.; supervision, R.J. and A.H.-F. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the Universidad de Jaén through its Teaching Innovation Plan (PID-UJA 2025–2029), under the Teaching Innovation Project “Diseño de entornos neurosaludables y afectivos en la universidad: prácticas neurodidácticas para la conexión docente–estudiante” (Project reference: PID2025_24 UJA), funded by the Vicerrectorado de Formación Permanente, Tecnologías Educativas e Innovación Docente.
Institutional Review Board Statement
This work is part of the research line titled Neuroscience, Neuroeducation, and Neurodidactics. Multiculturalism, Interculturalism, Intraculturalism, and Transculturalism. Sustainability in Education. The study was conducted in accordance with the Declaration of Helsinki and was approved by the Research Ethics Committee of the University of Jaén (Spain); approval code: JUL.22/4-LÍNEA; approval date: 20 July 2022.
Informed Consent Statement
Informed consent was obtained from all subjects involved in the study.
Data Availability Statement
The EEG and educational datasets generated and analysed during the current study contain information that could compromise the privacy of participants. For this reason, they are not publicly available but can be obtained from the corresponding author on reasonable request and subject to approval by the Research Ethics Committee of the University of Jaén.
Acknowledgments
We thank the participating students and the Universidad de Jaén for supporting the innovation project under which this research was conducted.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Luckin, R.; Holmes, W.; Griffiths, M.; Forcier, L.B. Intelligence Unleashed: An Argument for AI in Education; Pearson: London, UK, 2016; Available online: https://www.pearson.com/content/dam/one-dot-com/one-dot-com/global/Files/about-pearson/innovation/Intelligence-Unleashed-Publication.pdf (accessed on 30 December 2025).
- Holmes, W.; Bialik, M.; Fadel, C. Artificial Intelligence in Education: Promises and Implications for Teaching and Learning; Center for Curriculum Redesign: Boston, MA, USA, 2019; Available online: https://curriculumredesign.org/our-work/artificial-intelligence-in-education/ (accessed on 1 December 2025).
- Holmes, W.; Tuomi, I. State of the art and practice in AI in education. Eur. J. Educ. 2022, 57, 542–570. [Google Scholar] [CrossRef] [Scilit]
- OpenAI. Introducing ChatGPT. OpenAI Blog. 30 November 2022. Available online: https://openai.com/index/chatgpt/ (accessed on 1 December 2025).
- Kasneci, E.; Sessler, K.; Küchemann, S.; Bannert, M.; Dementieva, D.; Fischer, F.; Gasser, U.; Groh, G.; Günnemann, S.; Hüllermeier, E.; et al. ChatGPT for good? On opportunities and challenges of large language models for education. Learn. Individ. Differ. 2023, 103, 102274. [Google Scholar] [CrossRef] [Scilit]
- UNESCO. Guidance for Generative AI in Education and Research; UNESCO: Paris, France, 2023; Available online: https://unesdoc.unesco.org/ark:/48223/pf0000386693 (accessed on 1 December 2025).
- Dwivedi, Y.K.; Kshetri, N.; Hughes, L.; Slade, E.L.; Jeyaraj, A.; Kar, A.K.; Baabdullah, A.M.; Koohang, A.; Raghavan, V.; Ahuja, M.; et al. So what if ChatGPT wrote it? Multidisciplinary perspectives on opportunities, challenges and implications of generative conversational AI for research, practice and policy. Int. J. Inf. Manag. 2023, 71, 102642. [Google Scholar] [CrossRef] [Scilit]
- European Commission. Industry 5.0: Towards a Sustainable, Human-Centric and Resilient European Industry; Publications Office of the European Union: Luxembourg, 2021. [Google Scholar] [CrossRef]
- IEAIED. The Ethical Framework for AI in Education; The Institute for Ethical AI in Education: Buckingham, UK, 2021; Available online: https://www.buckingham.ac.uk/wp-content/uploads/2021/03/The-Institute-for-Ethical-AI-in-Education-The-Ethical-Framework-for-AI-in-Education.pdf (accessed on 1 December 2025).
- Immordino-Yang, M.H. Emotions, Learning, and the Brain: Exploring the Educational Implications of Affective Neuroscience; W.W. Norton & Company: New York, NY, USA, 2015; Available online: https://wwnorton.com/books/9780393709810 (accessed on 1 December 2025).
- Camacho-Morles, J.; Pekrun, R.; Loderer, K.; Salmela-Aro, K. Achievement Emotions and Academic Performance: A Meta-Analysis. Educ. Psychol. Rev. 2021, 33, 1051–1095. [Google Scholar] [CrossRef] [Scilit]
- Hernández-Fernández, A.; de Barros-Camargo, C. Desnudando el Cerebro: Neuropedagogía y Neuroimagen; Editorial GEU: Granada, Spain, 2024; ISBN 978-84-19646-68-2. [Google Scholar]
- Tokuhama-Espinosa, T. Neuromyths: Debunking False Ideas About the Brain; W.W. Norton & Company: New York, NY, USA, 2018; Available online: https://wwnorton.com/books/9780393713206 (accessed on 1 December 2025).
- Aricò, P.; Borghini, G.; Di Flumeri, G.; Colosimo, A.; Bonelli, S.; Golfetti, A.; Pozzi, S.; Imbert, J.P.; Granger, G.; Benhacene, R.; et al. Adaptive automation triggered by EEG-based mental workload index: A passive brain–computer interface application in realistic air traffic control environment. Front. Hum. Neurosci. 2016, 10, 539. [Google Scholar] [CrossRef] [Scilit]
- Matusz, P.J.; Dikker, S.; Huth, A.G.; Perrodin, C. Are we ready for real-world neuroscience? J. Cogn. Neurosci. 2019, 31, 327–338. [Google Scholar] [CrossRef] [Scilit]
- Polich, J. Updating P300: An Integrative Theory of P3a and P3b. Clin. Neurophysiol. 2007, 118, 2128–2148. [Google Scholar] [CrossRef] [Scilit]
- Başar, E.; Başar-Eroglu, C.; Karakaş, S.; Schürmann, M. Brain oscillations in perception and memory. Int. J. Psychophysiol. 2000, 35, 95–124. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Azevedo, R.; Gašević, D. Analyzing Multimodal Multichannel Data about Self-Regulated Learning with Advanced Learning Technologies. In Handbook of Self-Regulation of Learning and Performance, 2nd ed.; Schunk, D.H., Greene, J.A., Eds.; Routledge: New York, NY, USA, 2018; pp. 300–316. [Google Scholar] [CrossRef] [Scilit]
- Dede, C. Immersive Interfaces for Engagement and Learning. Science 2009, 323, 66–69. [Google Scholar] [CrossRef] [Scilit]
- D’Mello, S.K.; Graesser, A.C. Feeling, Thinking, and Computing with Affect-Aware Learning Technologies. In The Oxford Handbook of Affective Computing; Calvo, R.A., D’Mello, S.K., Gratch, J., Kappas, A., Eds.; Oxford University Press: Oxford, UK, 2015; pp. 419–434. [Google Scholar] [CrossRef] [Scilit]
- du Boulay, B.; Mitrovic, A.; Yacef, K. (Eds.) Handbook of Artificial Intelligence in Education; Edward Elgar Publishing: Cheltenham, UK, 2023; Available online: https://www.e-elgar.com/shop/gbp/handbook-of-artificial-intelligence-in-education-9781800375406.html (accessed on 1 December 2025).
- Woolf, B.P. Building Intelligent Interactive Tutors: Student-Centered Strategies for Revolutionizing E-Learning; Morgan Kaufmann: Burlington, MA, USA, 2010; Available online: https://www.sciencedirect.com/book/9780123735942/building-intelligent-interactive-tutors (accessed on 1 December 2025).
- Panadero, E. A Review of Self-Regulated Learning: Six Models and Four Directions for Research. Front. Psychol. 2017, 8, 422. [Google Scholar] [CrossRef] [Scilit]
- Hedi, A.; Khraief, N.; Böttcher, A. Adoption and usage of ChatGPT in higher education: A systematic literature review. J. Inf. Technol. Educ. Res. 2024, 23, 267–304. [Google Scholar] [CrossRef] [Scilit]
- Xu, X.; Zhong, B. A review on portable EEG technology in educational research. Comput. Hum. Behav. 2018, 81, 340–349. [Google Scholar] [CrossRef] [Scilit]
- Yang, J.; Neville, C.; Ní Riordáin, M. Mobile EEG in Education: A Scoping Review. J. Neuroeduc. 2025, 6, 50324. [Google Scholar] [CrossRef] [Scilit]
- Selwyn, N. Should Robots Replace Teachers? AI and the Future of Education; Polity Press: Cambridge, UK, 2019; Available online: https://politybooks.com/should-robots-replace-teachers/ (accessed on 1 December 2025).
- Selwyn, N. The future of AI and education: Some cautionary notes. Eur. J. Educ. 2022, 57, 620–631. [Google Scholar] [CrossRef] [Scilit]
- Knox, J. AI and Education in China: Imagining the Future, Excavating the Past; Routledge: London, UK, 2023. [Google Scholar] [CrossRef] [Scilit]
- Williamson, B. The Social Life of AI in Education. Int. J. Artif. Intell. Educ. 2024, 34, 97–104. [Google Scholar] [CrossRef] [Scilit]
- Williamson, B.; Eynon, R.; Knox, J.; Davies, H.C. Critical perspectives on AI in education: Political economy, discrimination, commercialization, governance and ethics. In Handbook of Artificial Intelligence in Education; du Boulay, B., Mitrovic, A., Yacef, K., Eds.; Edward Elgar Publishing: Cheltenham, UK, 2023; pp. 555–573. Available online: https://www.e-elgar.com/shop/gbp/handbook-of-artificial-intelligence-in-education-9781800375406.html (accessed on 1 December 2025).
- Williamson, B.; Molnar, A.; Boninger, F. Time for a Pause: Without Effective Public Oversight, AI in Schools Will Do More Harm than Good; National Education Policy Center: Boulder, CO, USA, 2024; Available online: https://nepc.colorado.edu/publication/ai (accessed on 1 December 2025).
- Creswell, J.W.; Creswell, J.D. Research Design: Qualitative, Quantitative, and Mixed Methods Approaches, 5th ed.; SAGE: Thousand Oaks, CA, USA, 2018. [Google Scholar]
- Freire, P. Pedagogy of Hope: Reliving Pedagogy of the Oppressed; Bloomsbury Academic: London, UK, 2014. [Google Scholar]
- Freire, P. Pedagogy of the Oppressed, 50th Anniversary ed.; Bloomsbury Academic: New York, NY, USA, 2018; Available online: https://www.bloomsbury.com/us/pedagogy-of-the-oppressed-9781501314131/ (accessed on 1 December 2025).
- Balalle, H.; Pannilage, S. Reassessing academic integrity in the age of AI: A systematic literature review on AI and academic integrity. Soc. Sci. Humanit. Open 2025, 11, 101299. [Google Scholar] [CrossRef] [Scilit]
- Baig, M.I.; Yadegaridehkordi, E. ChatGPT in the higher education: A systematic literature review and research challenges. Int. J. Educ. Res. 2024, 127, 102411. [Google Scholar] [CrossRef] [Scilit]
- Chen, J.; Qian, P.; Gao, X.; Li, B.; Zhang, Y.; Zhang, D. Inter-brain coupling reflects disciplinary differences in real-world classroom learning. npj Sci. Learn. 2023, 8, 11. [Google Scholar] [CrossRef] [Scilit]
- Giannakos, M.N.; Ifenthaler, D.; Sharma, K.; Ouyang, F.; Vlachopoulos, D.; Pappas, I.O.; Sharma, R.C. The promise and challenges of generative AI in education. Behav. Inf. Technol. 2025, 44, 2518–2544. [Google Scholar] [CrossRef] [Scilit]
- Hwang, G.J.; Xie, H.; Wah, B.W.; Gašević, D. Vision, challenges, roles and research issues of Artificial Intelligence in Education. Comput. Educ. Artif. Intell. 2020, 1, 100001. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Gu, X. A Risk Framework for Human-Centered Artificial Intelligence in Education: Based on Literature Review and Delphi–AHP Method. Educ. Technol. Soc. 2023, 26, 187–202. [Google Scholar] [CrossRef]
- Holmes, W.; Porayska-Pomsta, K.; Holstein, K.; Sutherland, E.; Baker, T.; Shum, S.B.; Santos, O.C.; Rodrigo, M.T.; Cukurova, M.; Bittencourt, I.I.; et al. Ethics of AI in Education: Towards a Community-Wide Framework. Int. J. Artif. Intell. Educ. 2022, 32, 504–526. [Google Scholar] [CrossRef] [Scilit]
- Hayes, A.F.; Coutts, J.J. Use Omega rather than Cronbach’s alpha for estimating reliability. But.. Commun. Methods Meas. 2020, 14, 1–24. [Google Scholar] [CrossRef] [Scilit]
- Hu, L.T.; Bentler, P.M. Cutoff criteria for fit indexes in covariance structure analysis: Conventional criteria versus new alternatives. Struct. Equ. Model. 1999, 6, 1–55. [Google Scholar] [CrossRef] [Scilit]
- Kline, R.B. Principles and Practice of Structural Equation Modeling, 5th ed.; The Guilford Press: New York, NY, USA, 2023. [Google Scholar]
- García-Monge, A.; Rodríguez-Navarro, H.; Marbán, J.-M. Potentialities and limitations of the use of EEG devices in educational contexts. Comunicar 2023, 31, 47–58. [Google Scholar] [CrossRef] [Scilit]
- Montenegro-Rueda, M.; Fernández-Cerero, J.; Fernández-Batanero, J.M.; López-Meneses, E. Impact of the Implementation of ChatGPT in Education: A Systematic Review. Computers 2023, 12, 153. [Google Scholar] [CrossRef] [Scilit]
- NIST. Artificial Intelligence Risk Management Framework (AI RMF 1.0); (NIST AI 100-1); National Institute of Standards and Technology: Gaithersburg, MD, USA, 2023. [Google Scholar] [CrossRef] [Scilit]
- European Union. Regulation (EU) 2024/1689 Laying Down Harmonised Rules on Artificial Intelligence (Artificial Intelligence Act). Official Journal of the European Union. 2024. Available online: https://eur-lex.europa.eu/eli/reg/2024/1689/oj (accessed on 30 December 2025).
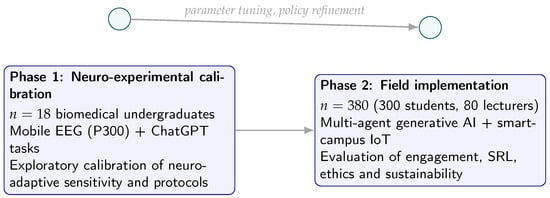
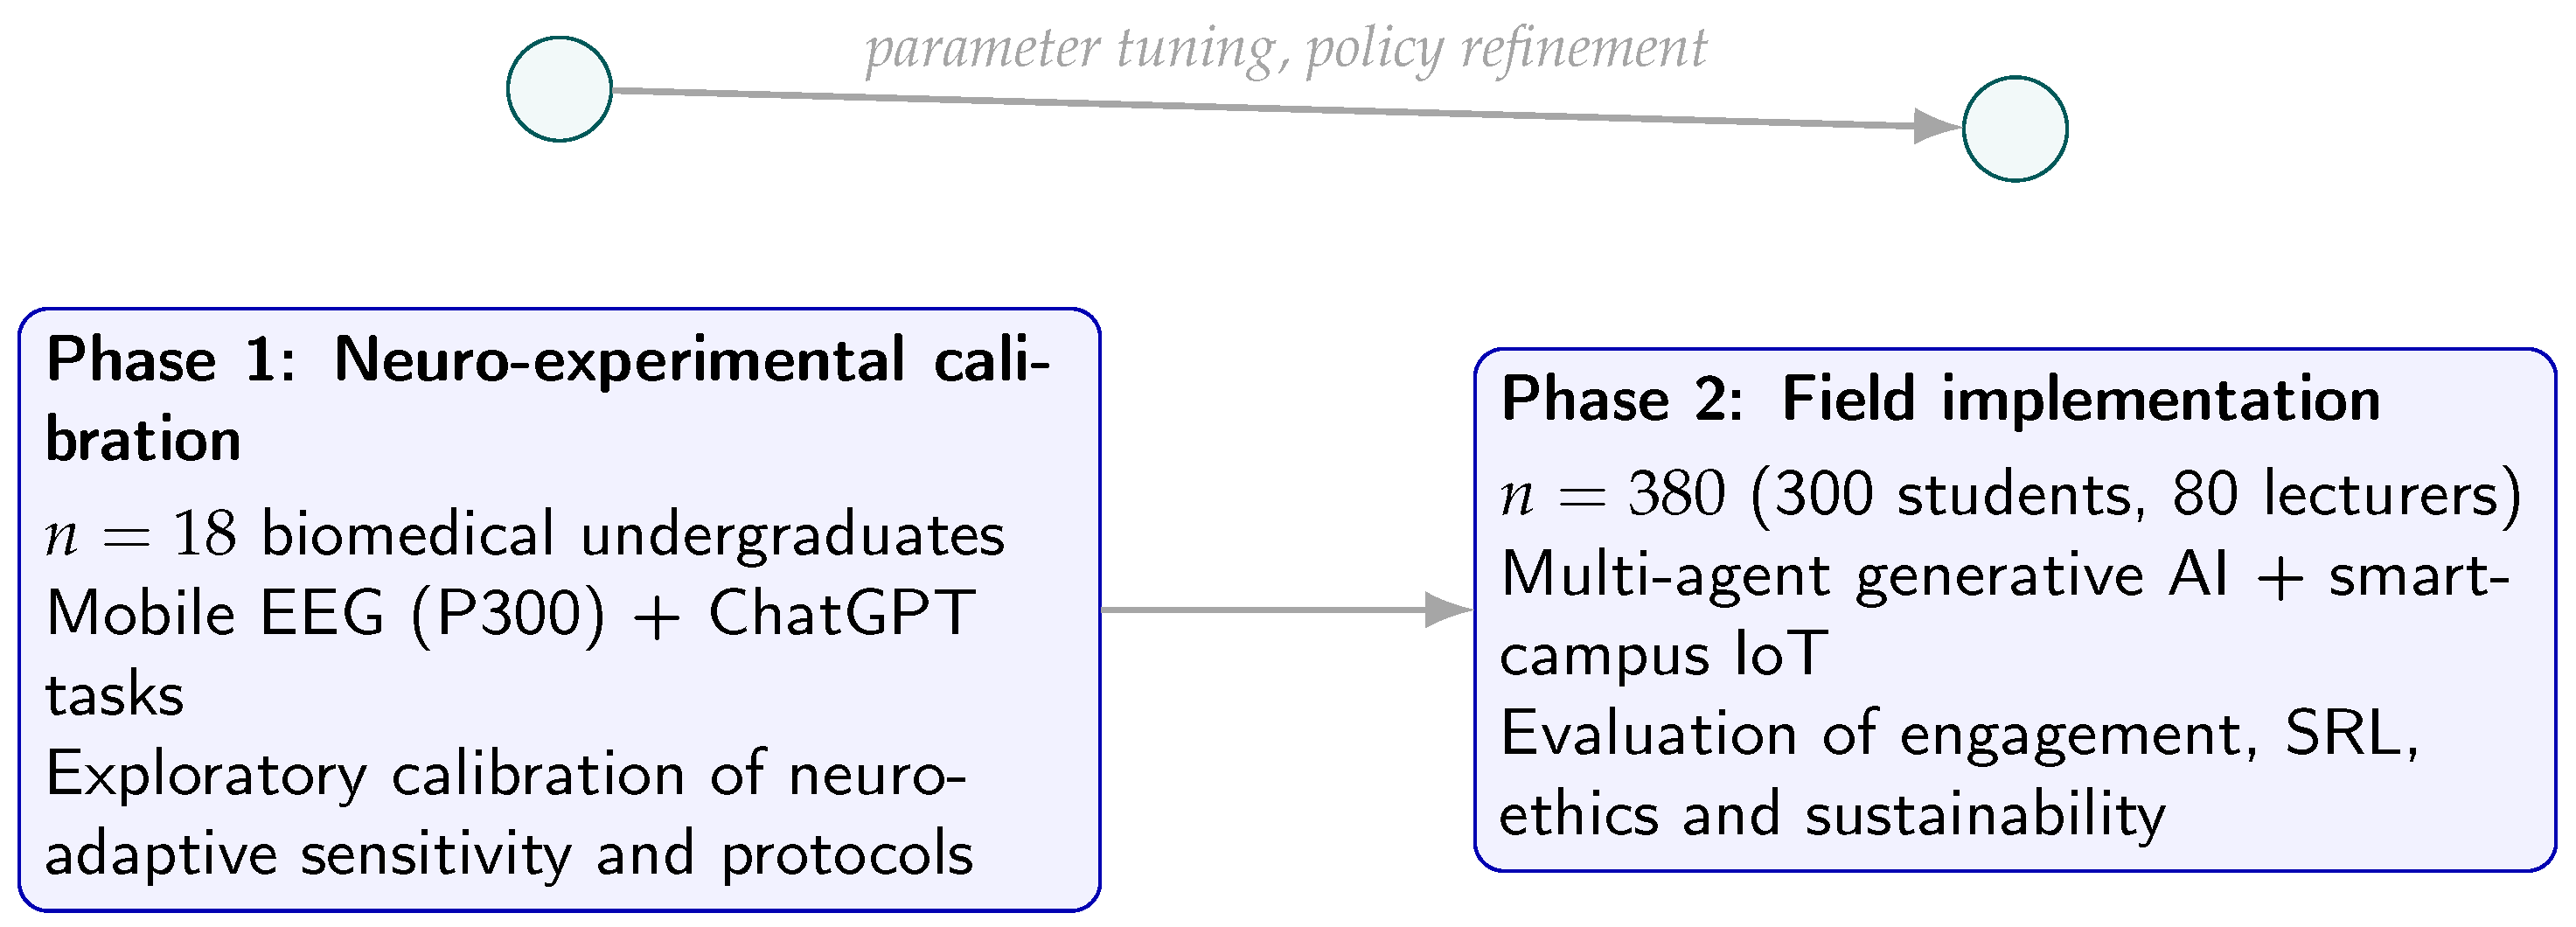
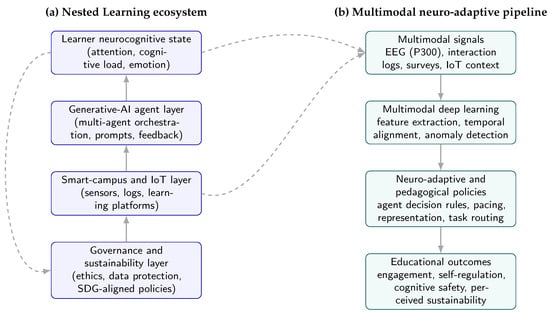
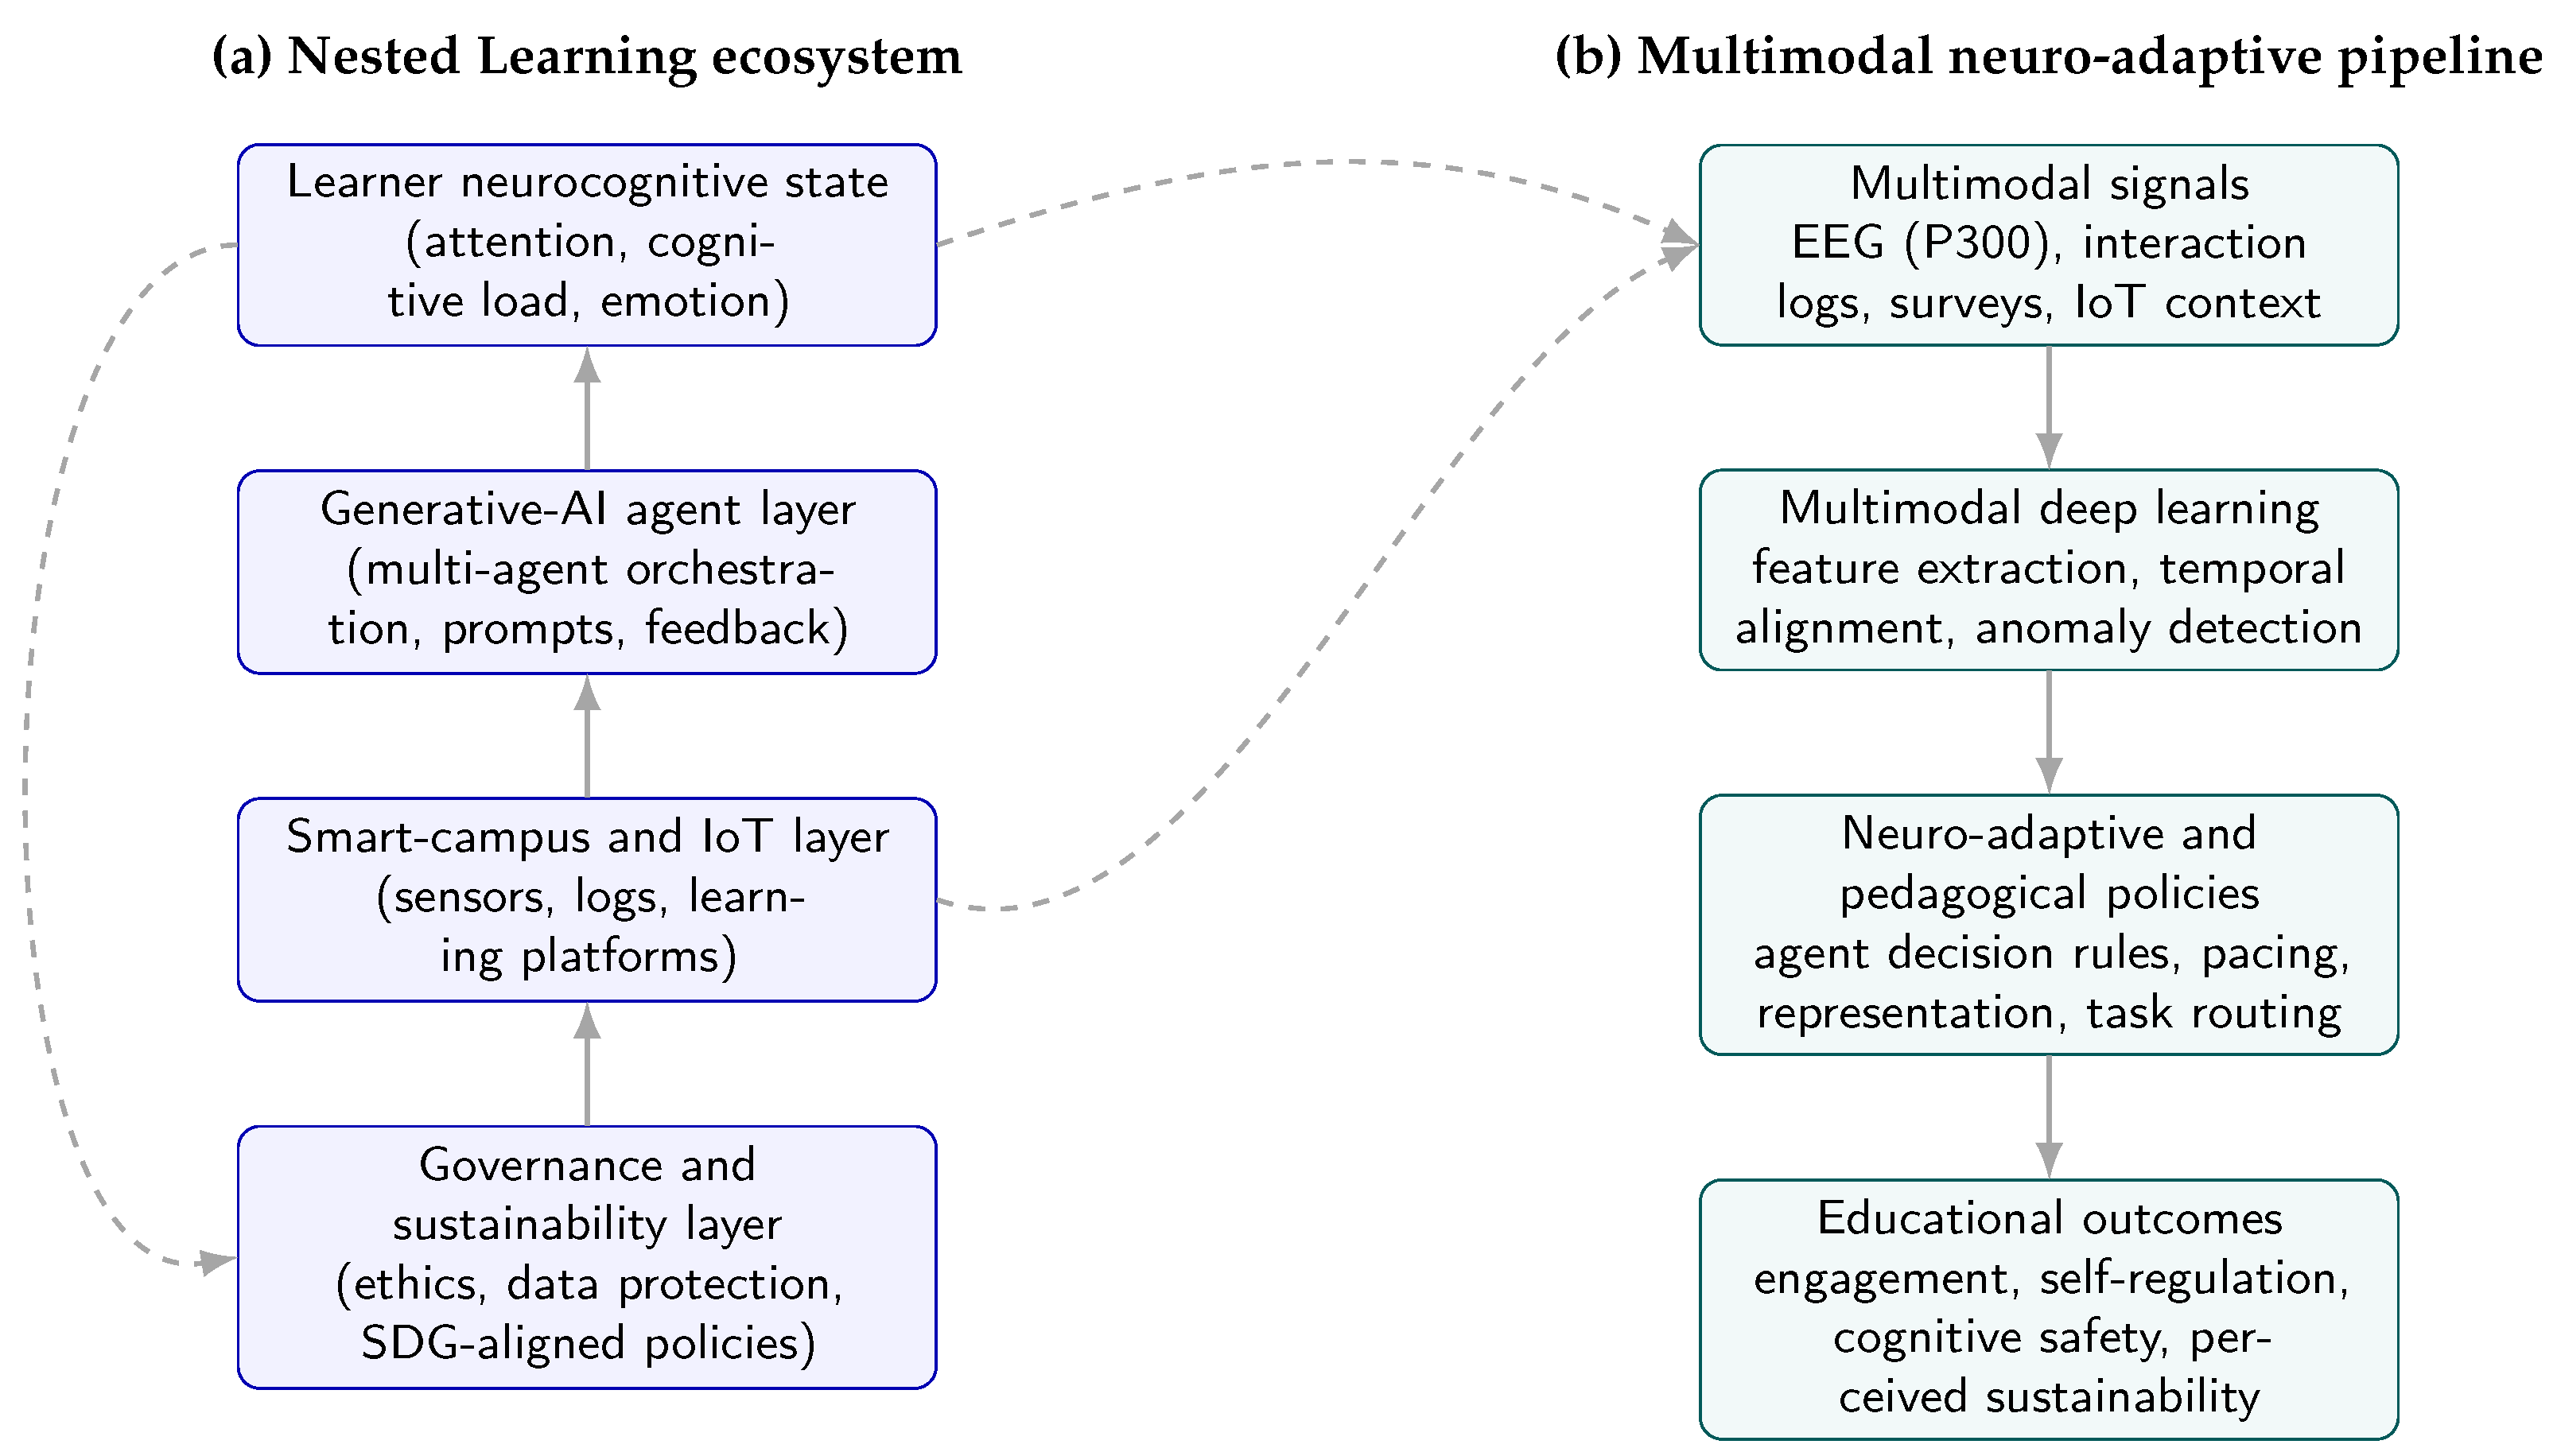
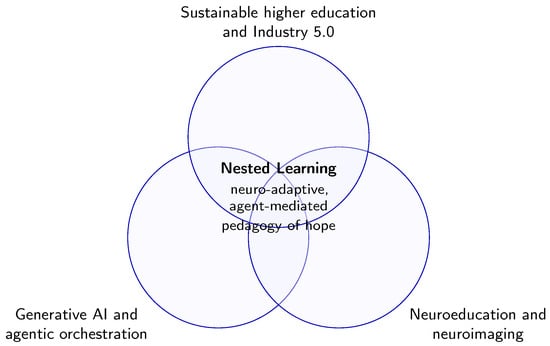
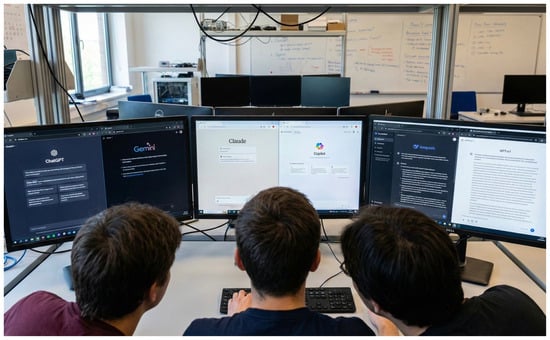
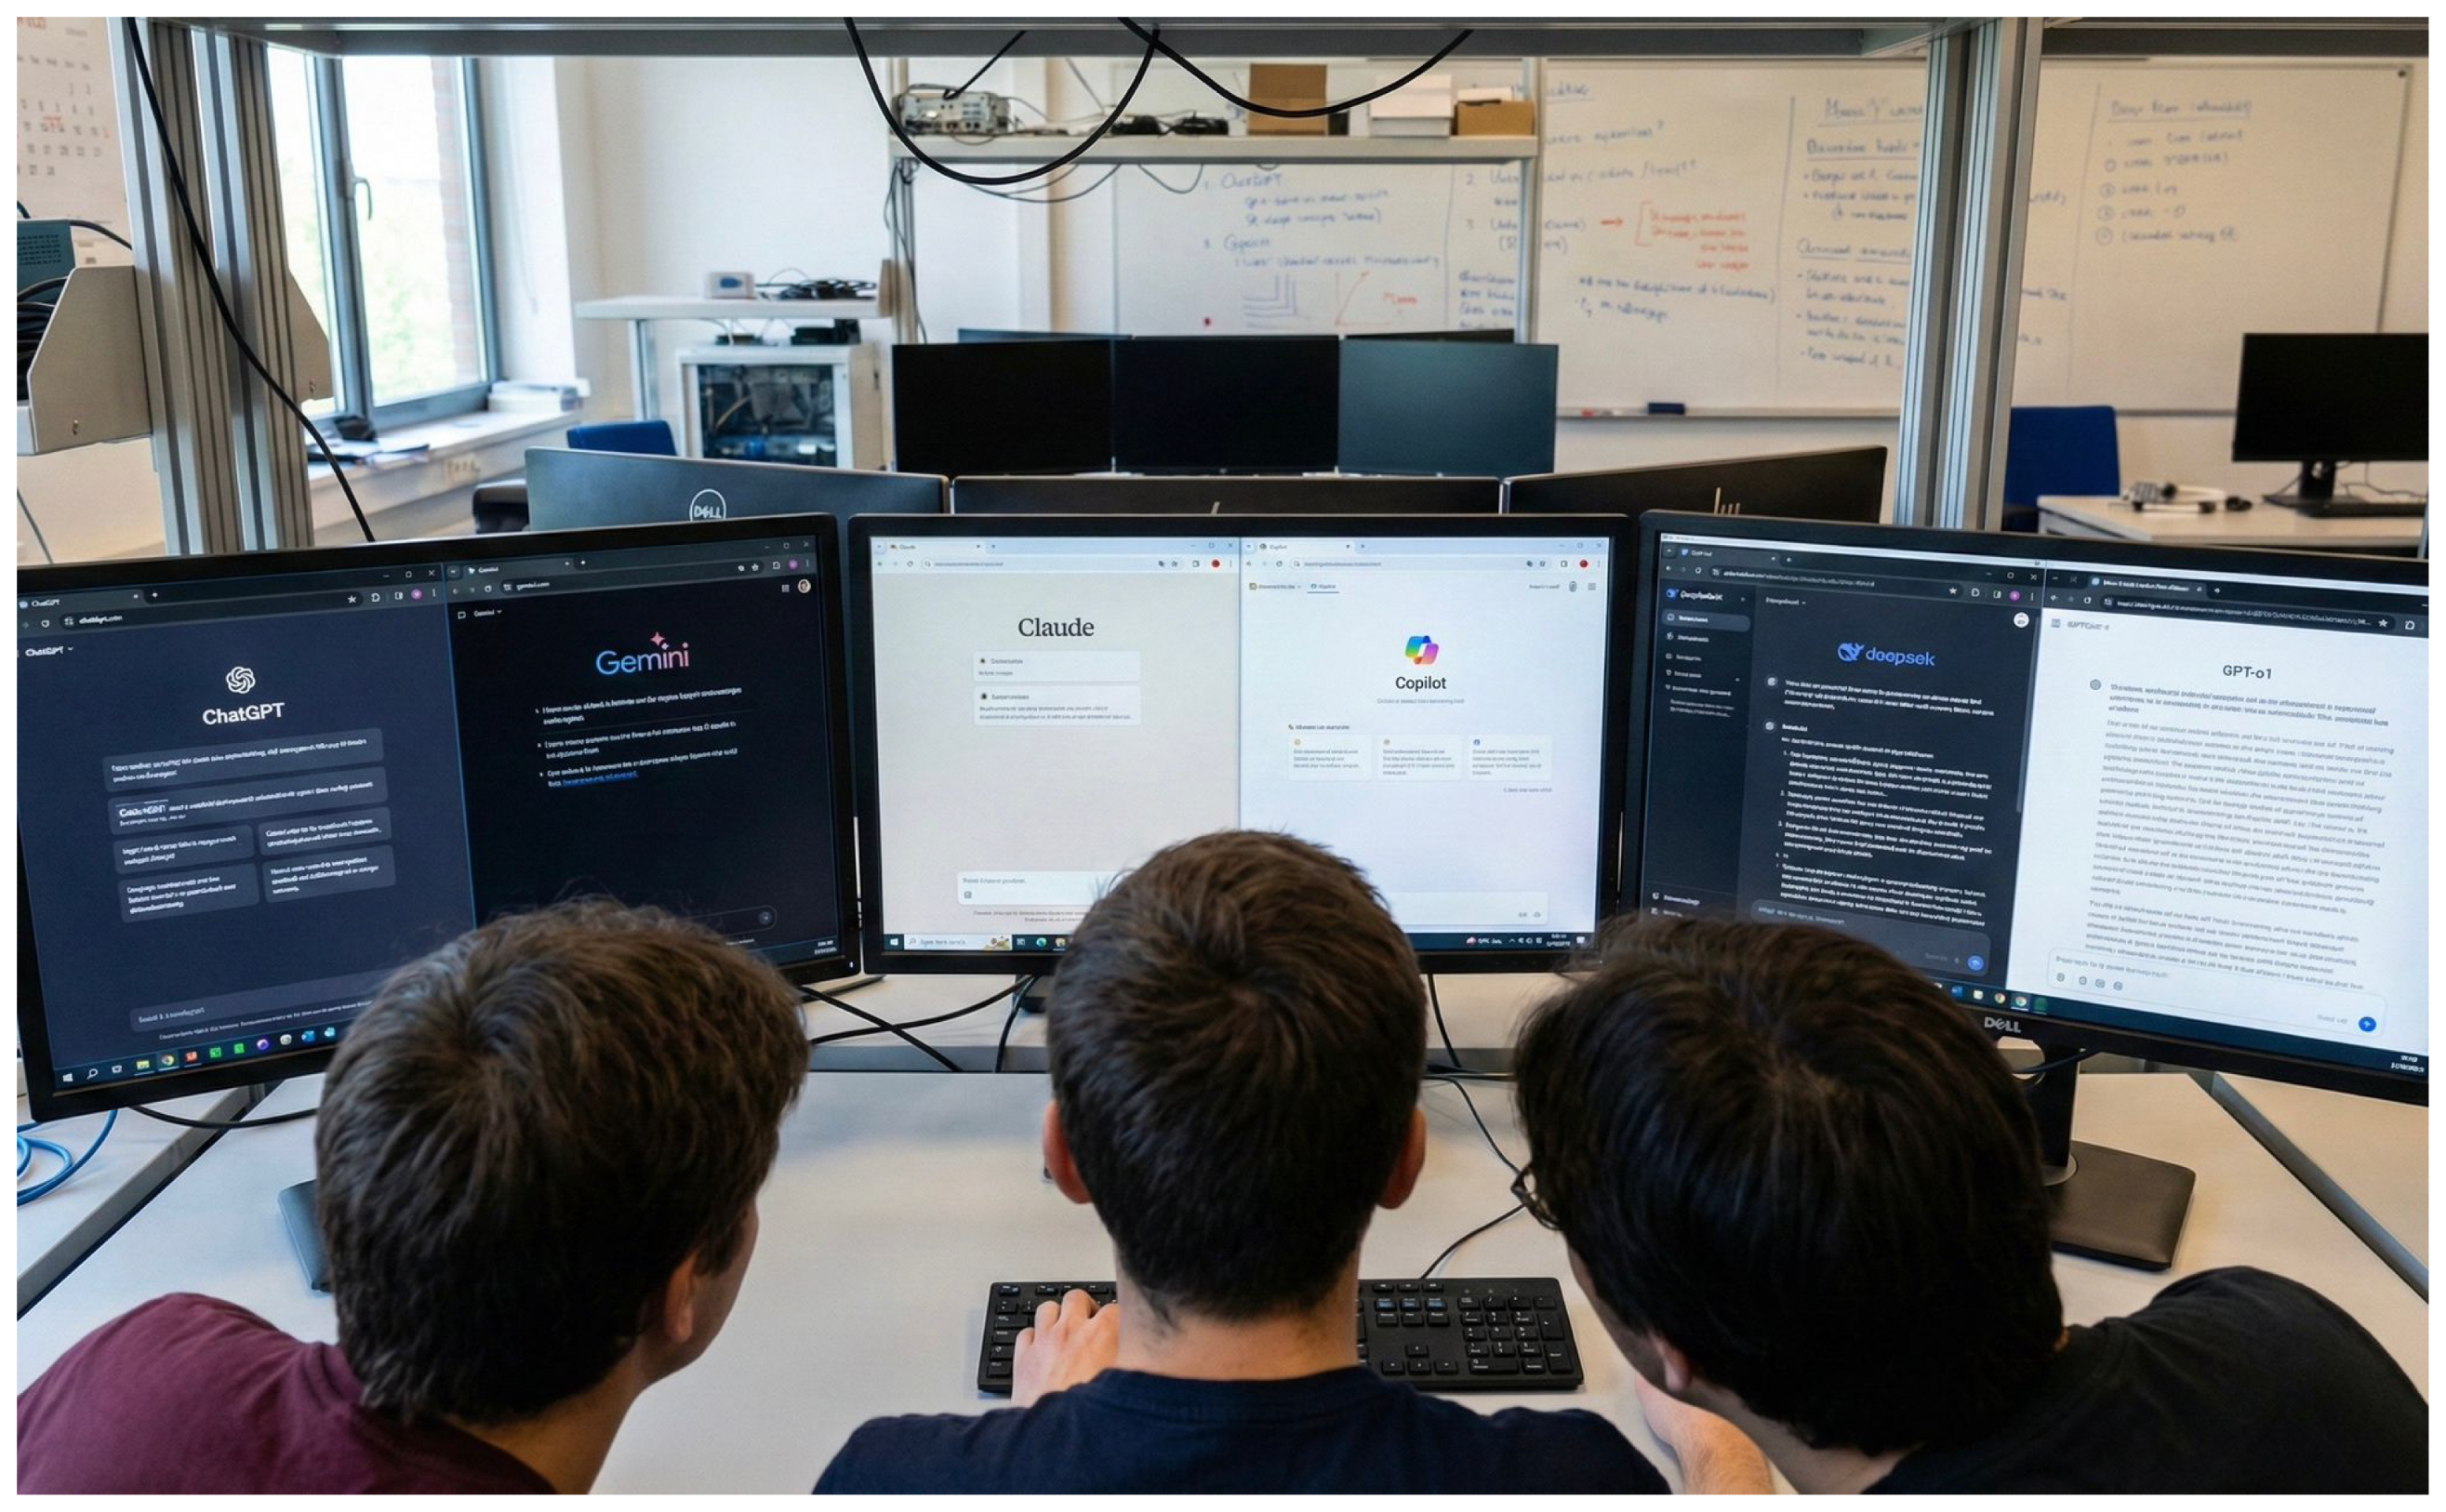
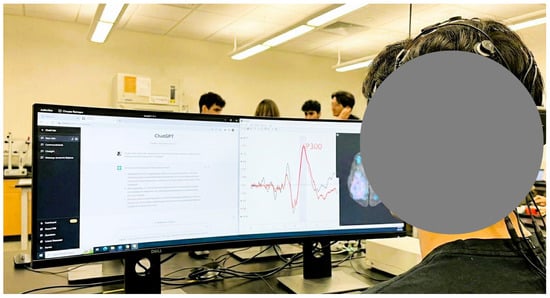
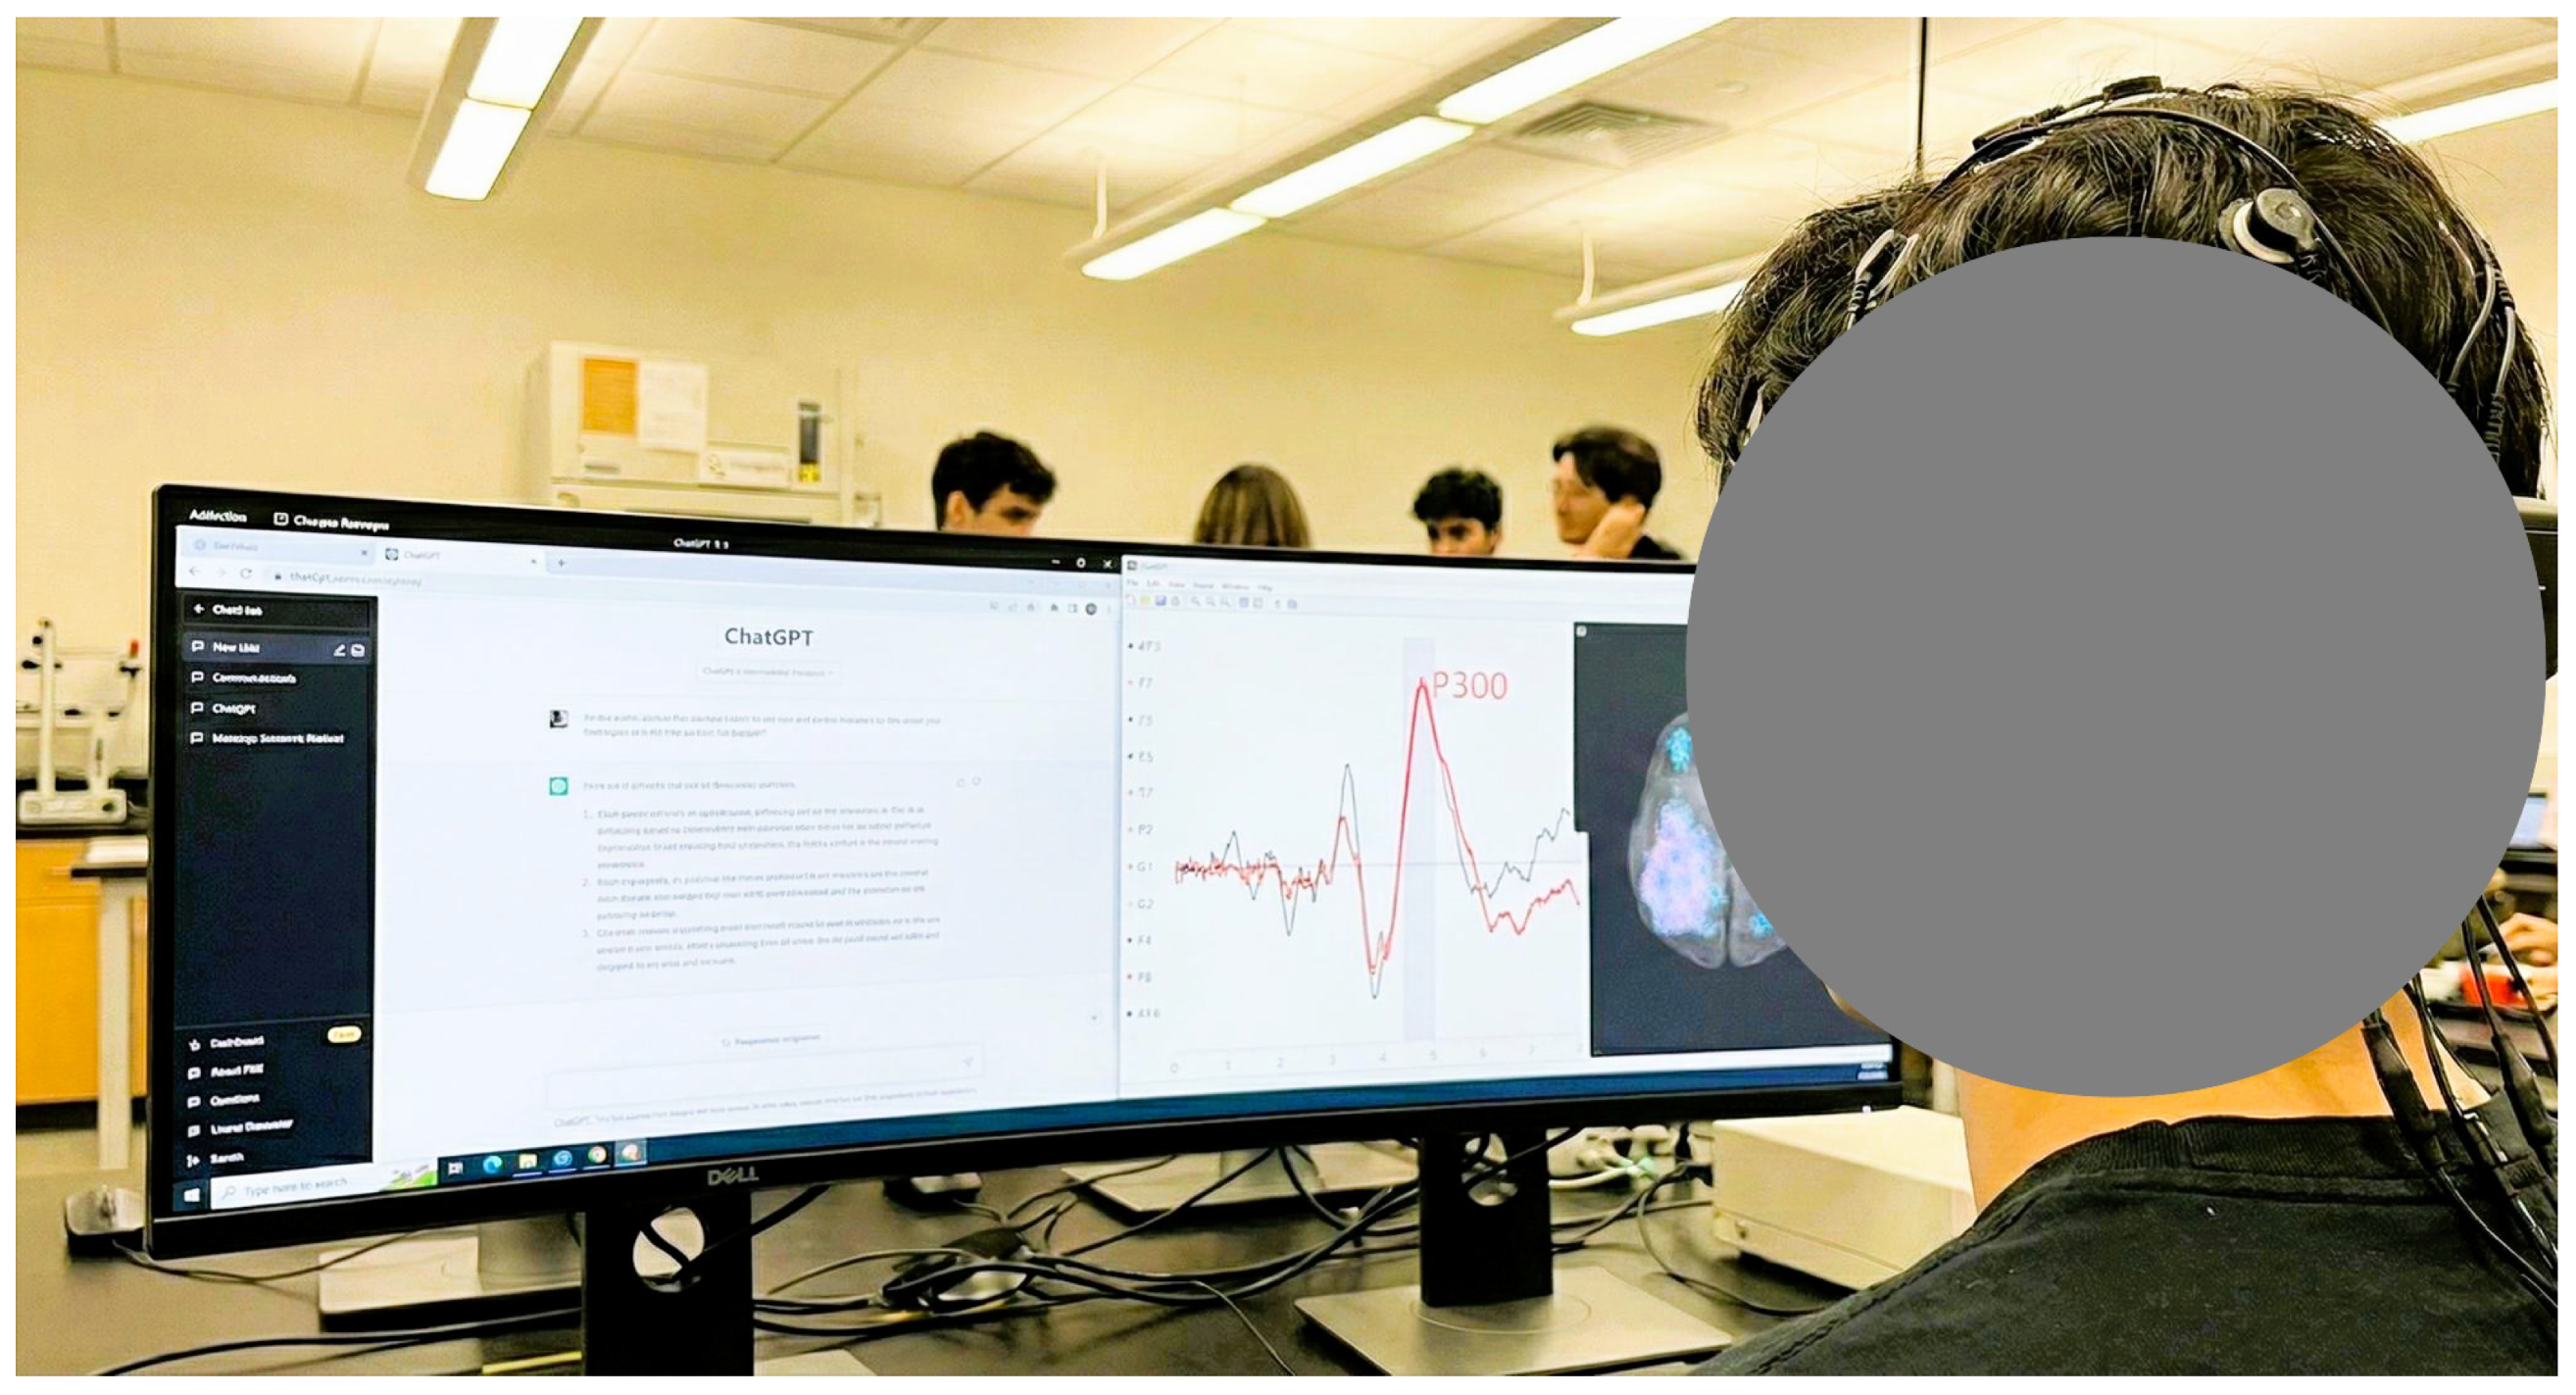
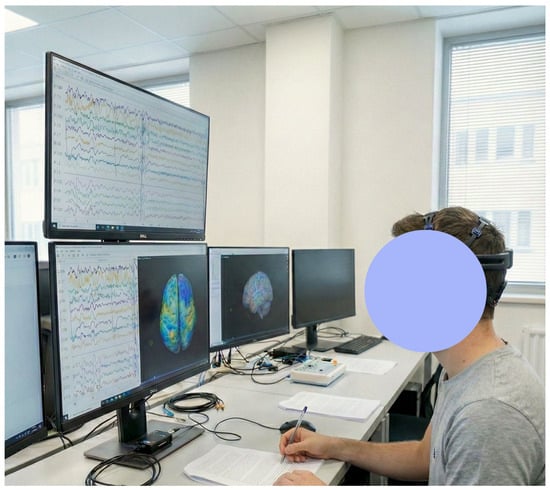
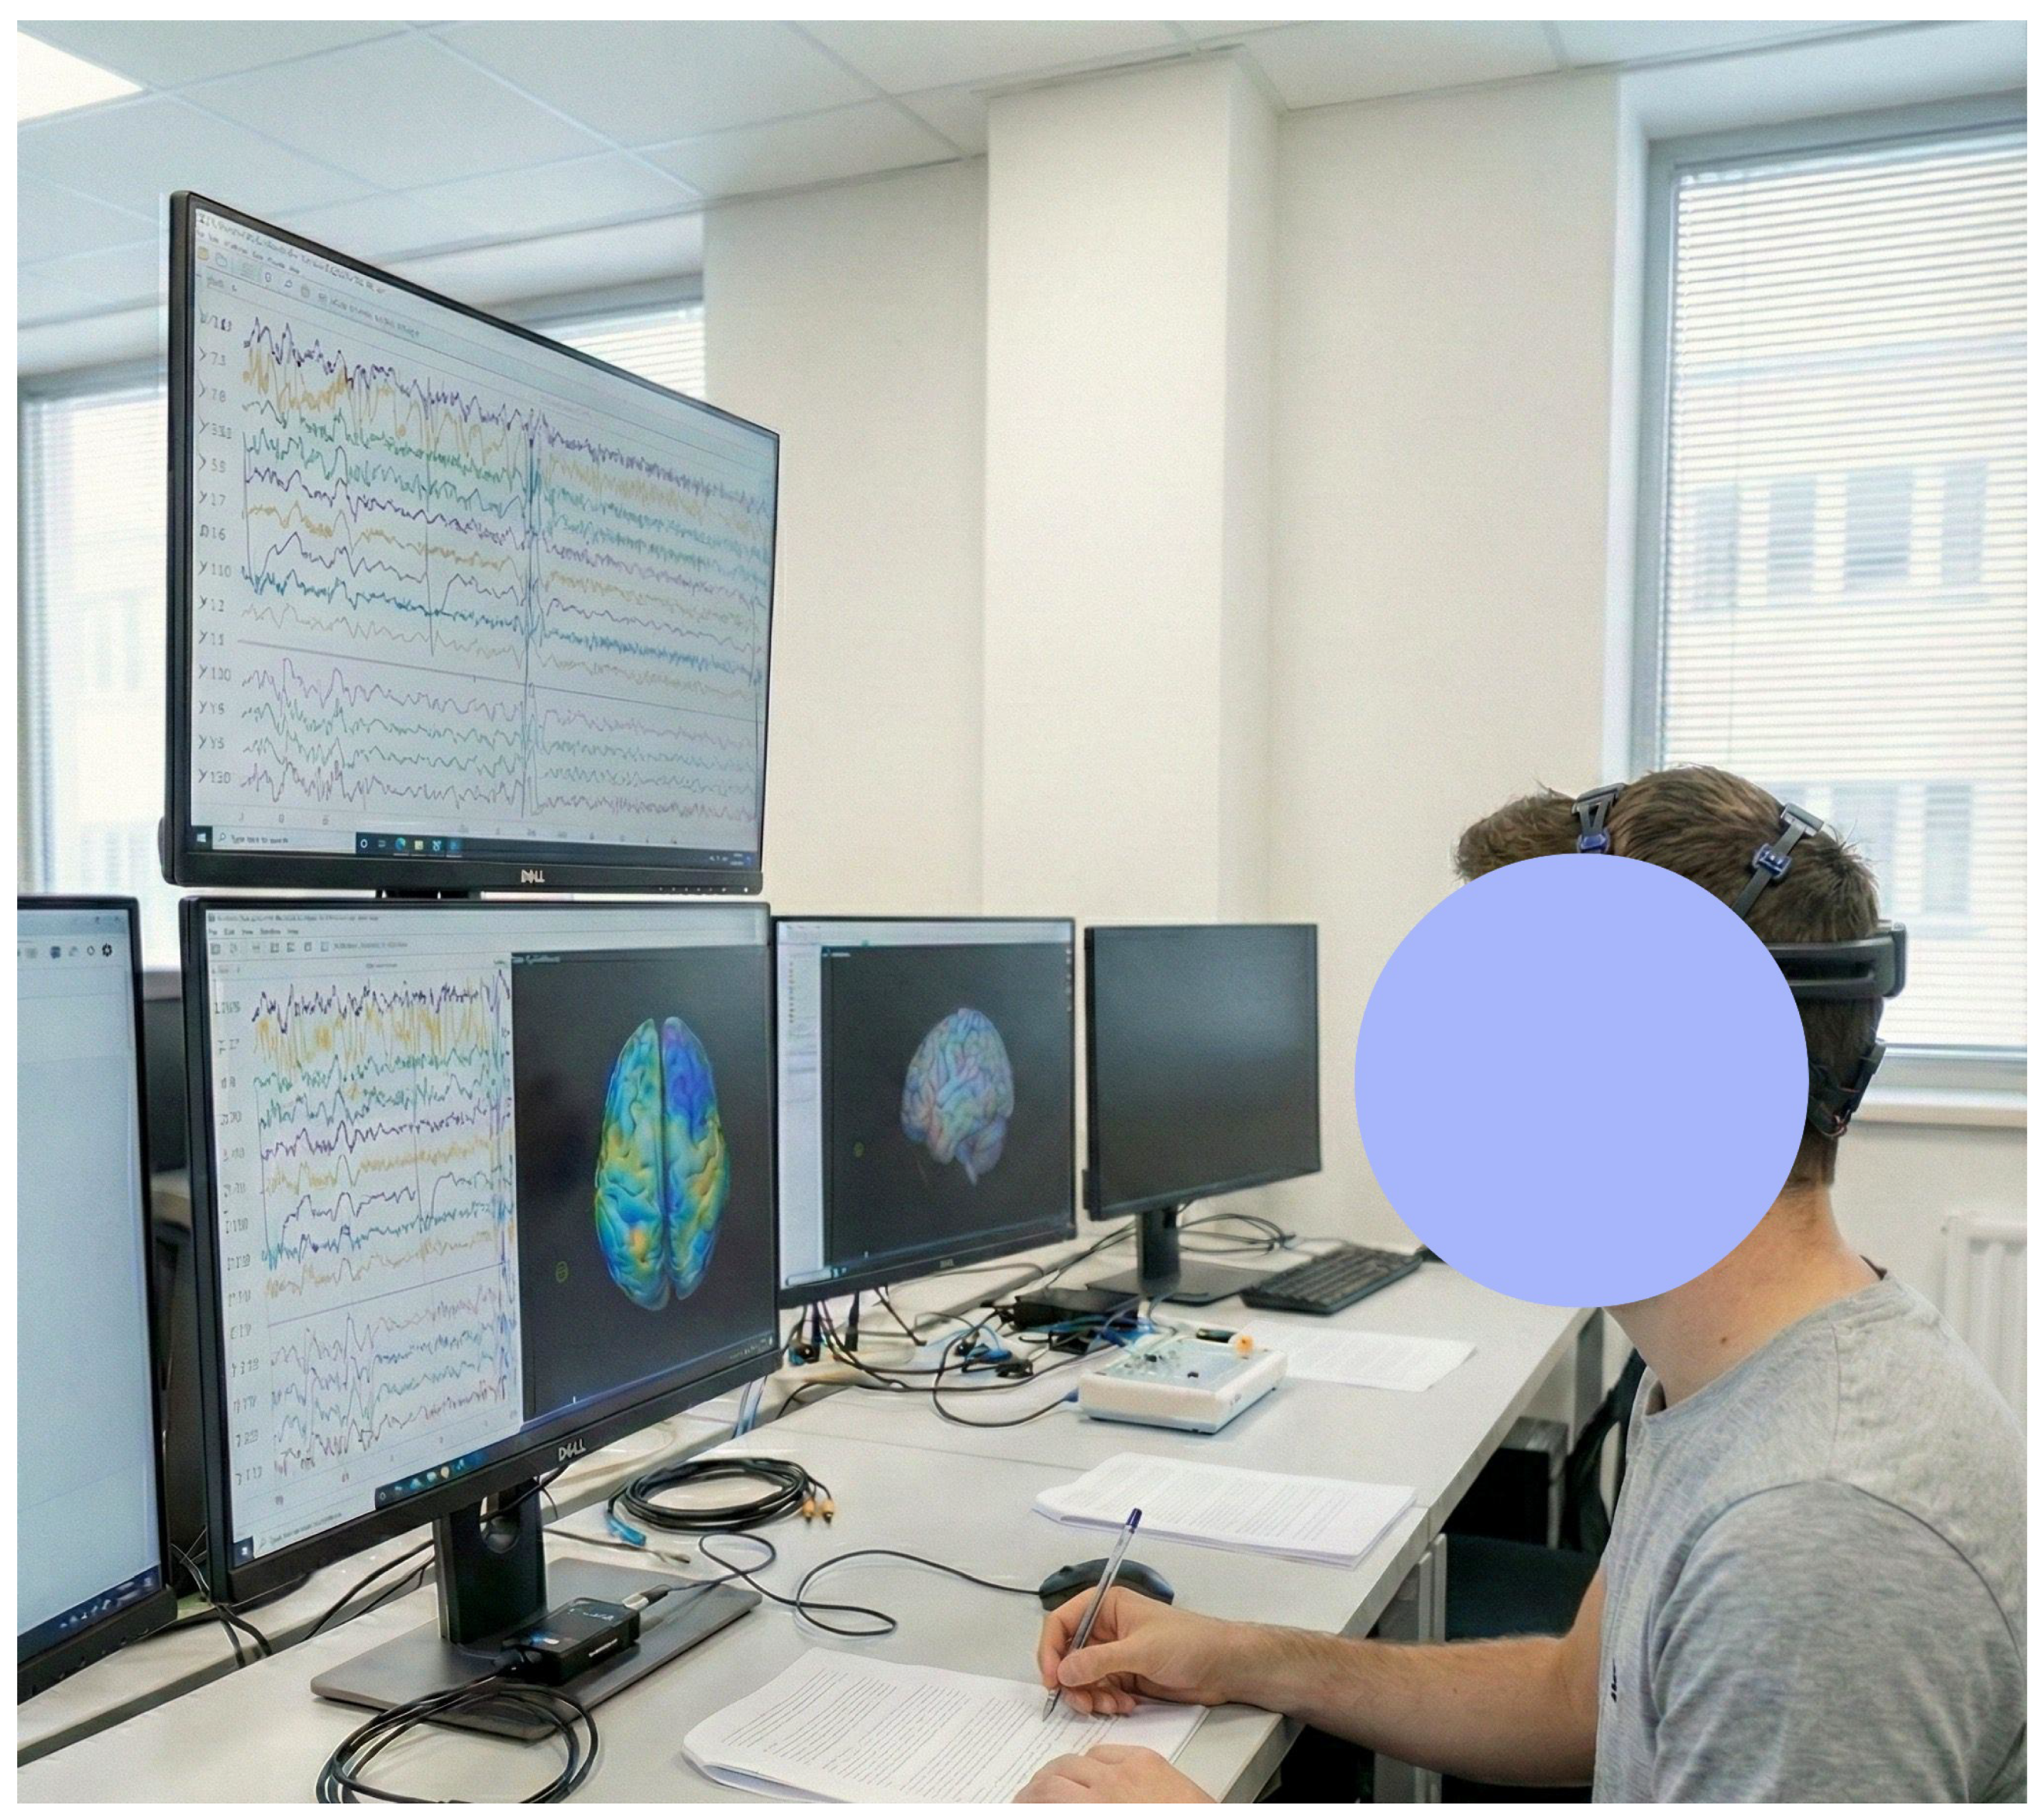
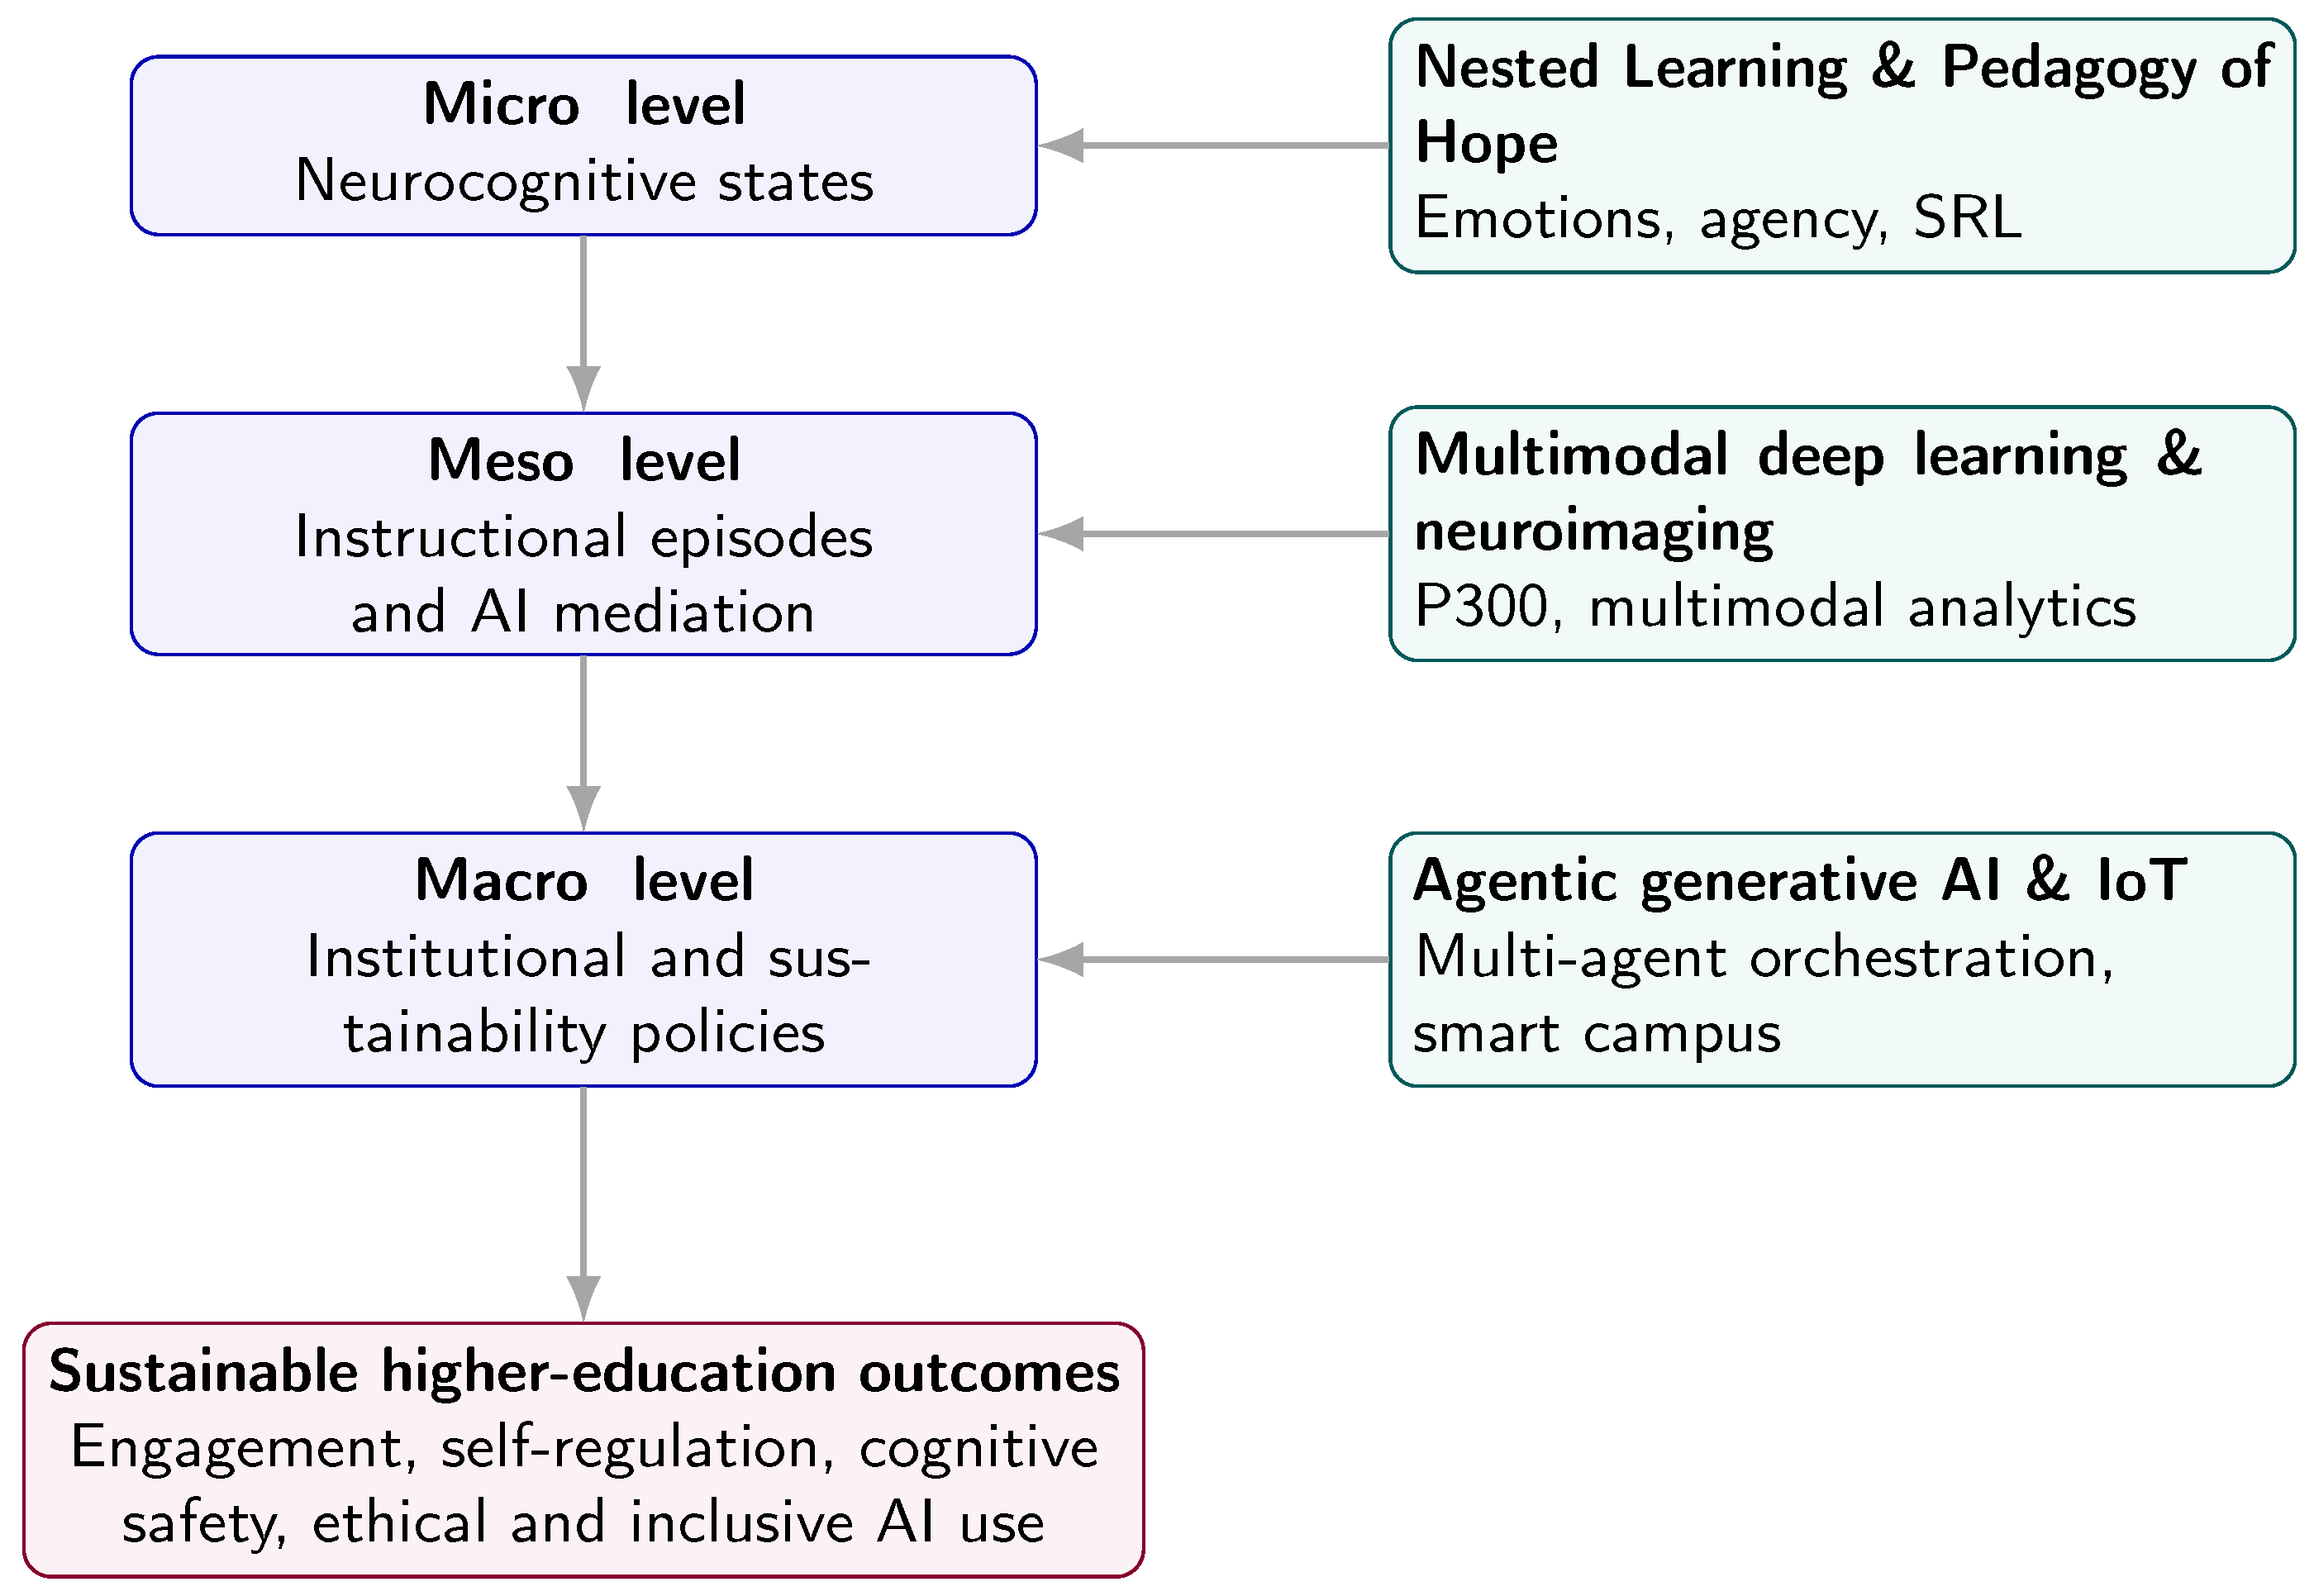
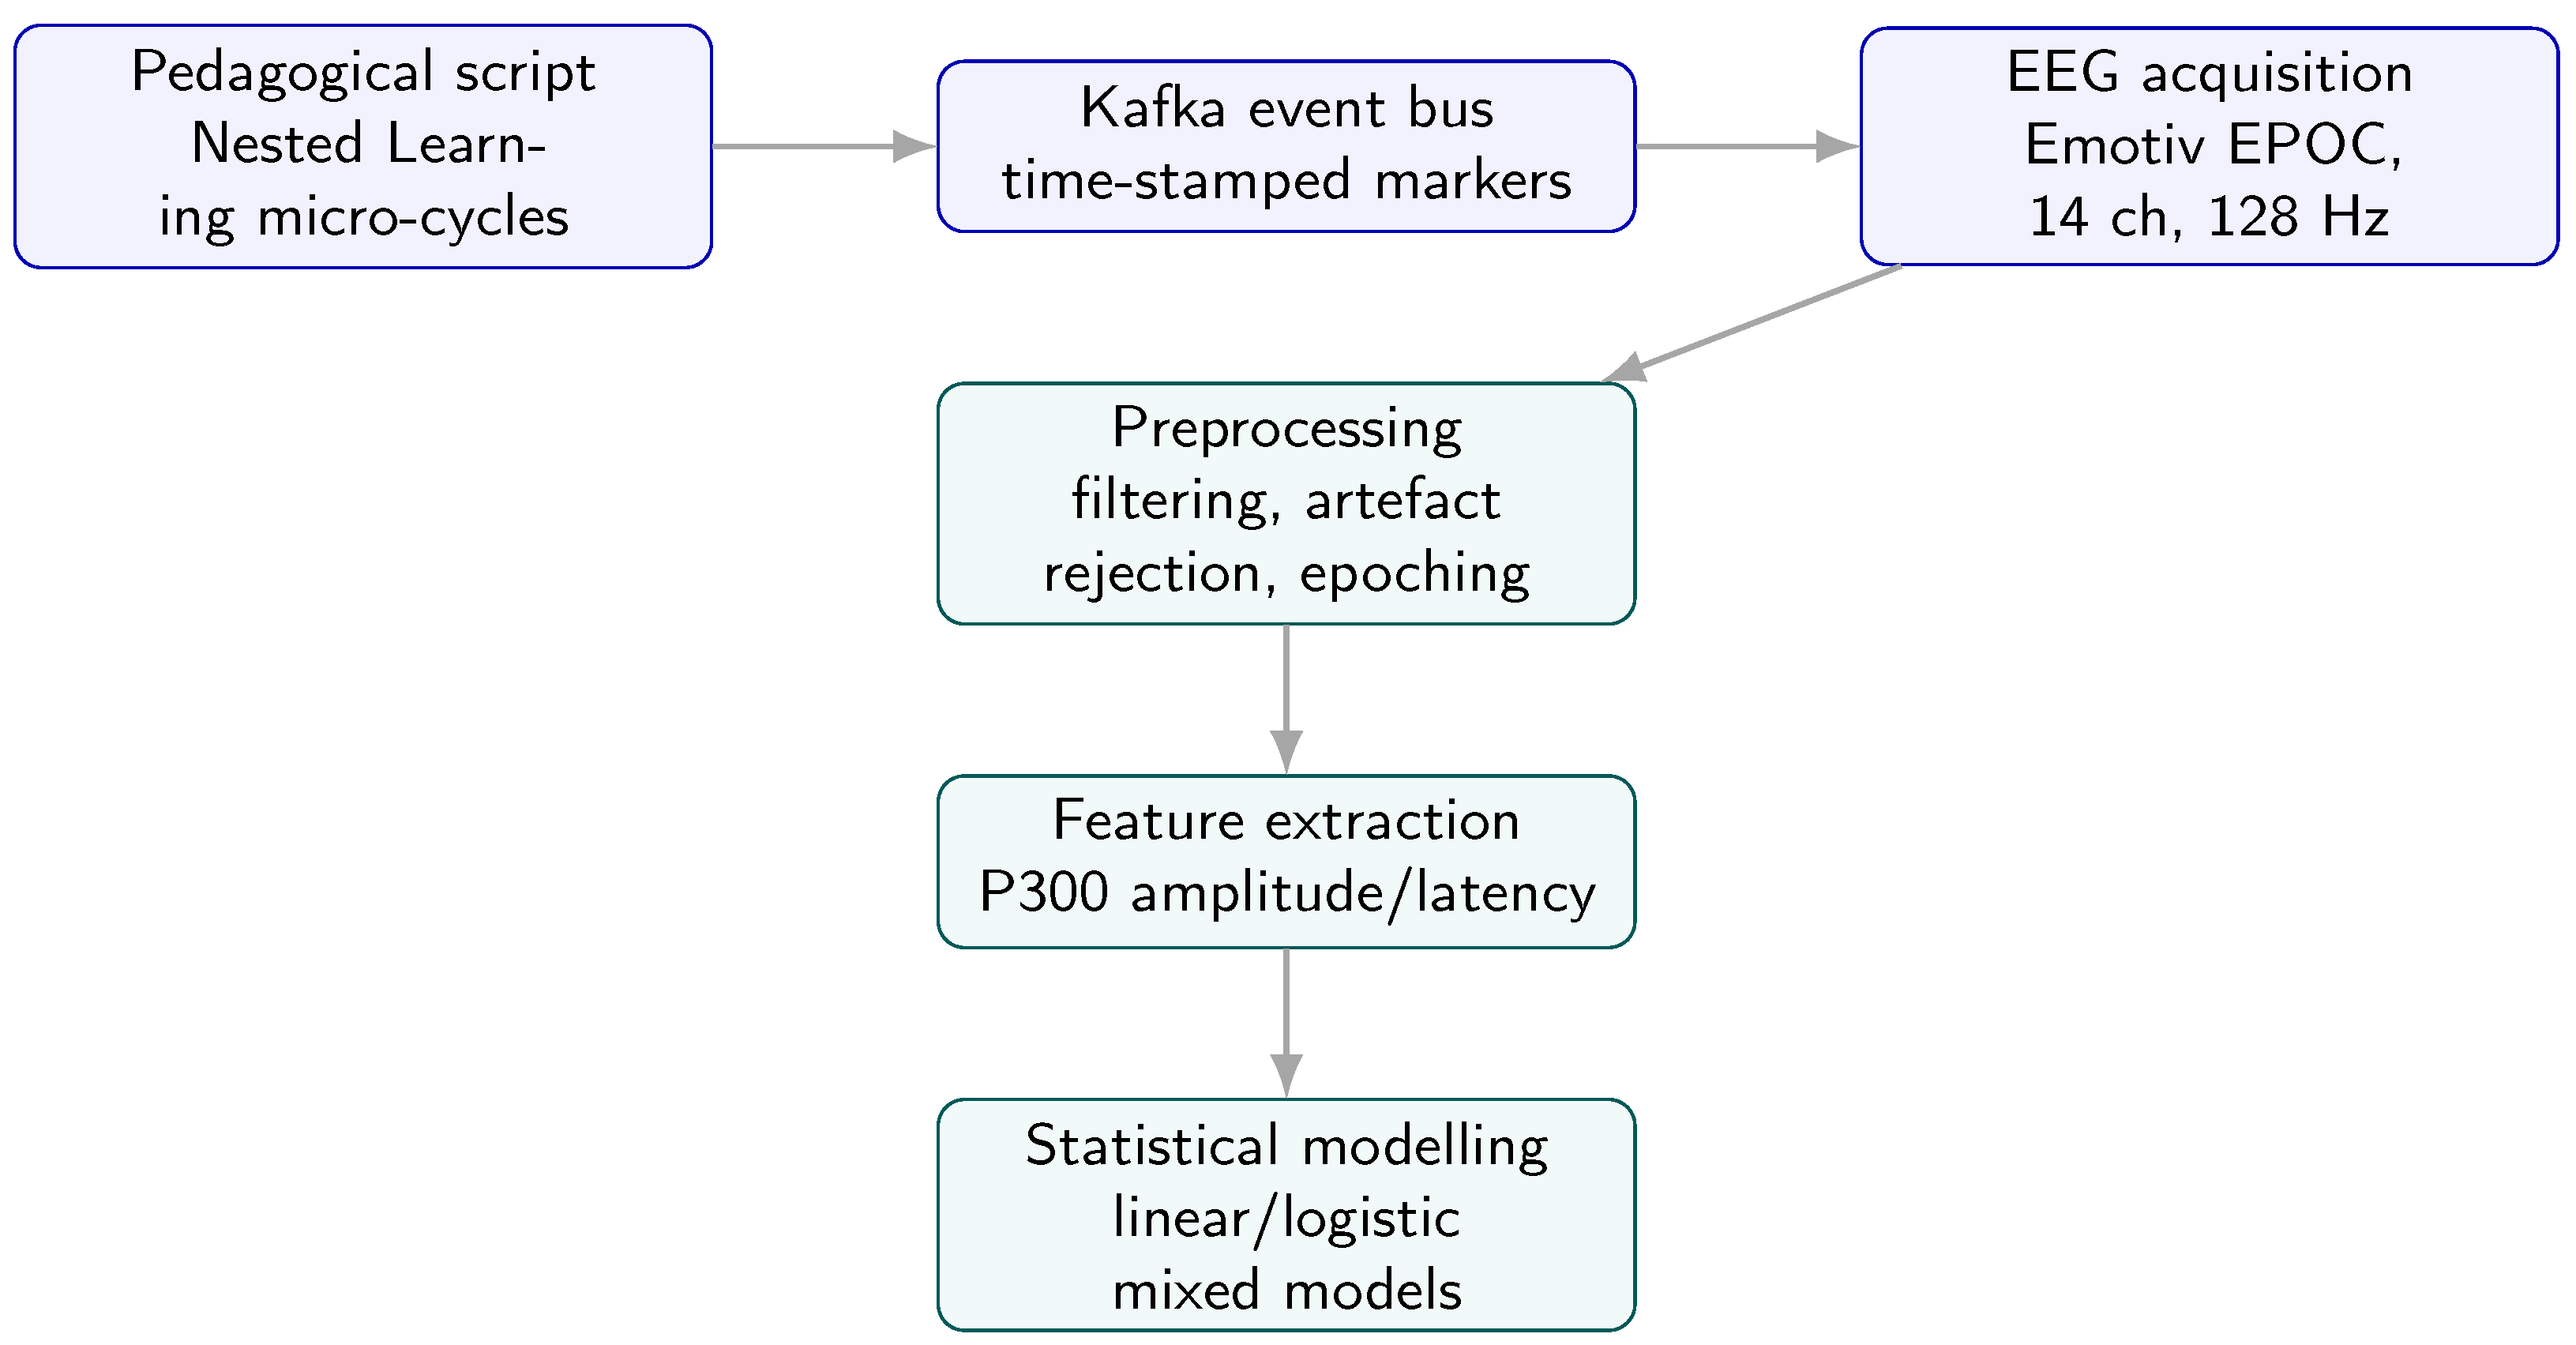
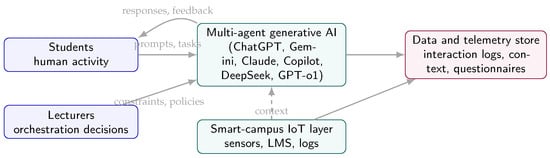
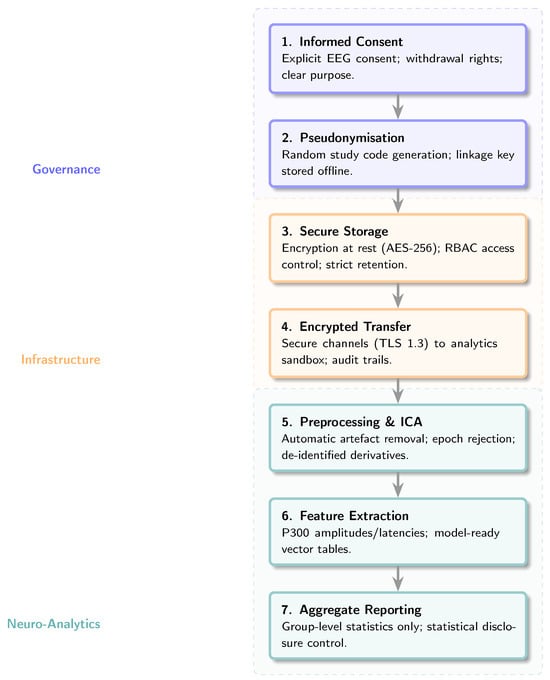
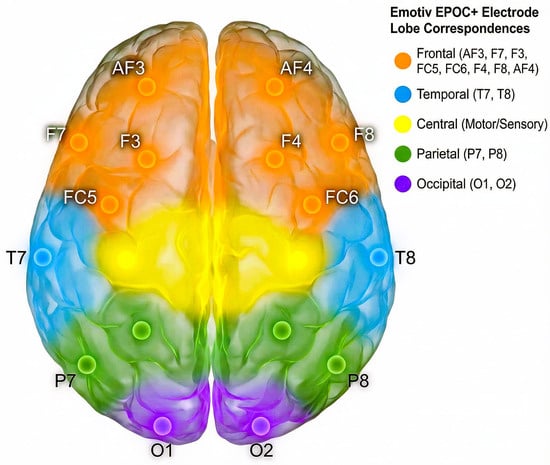
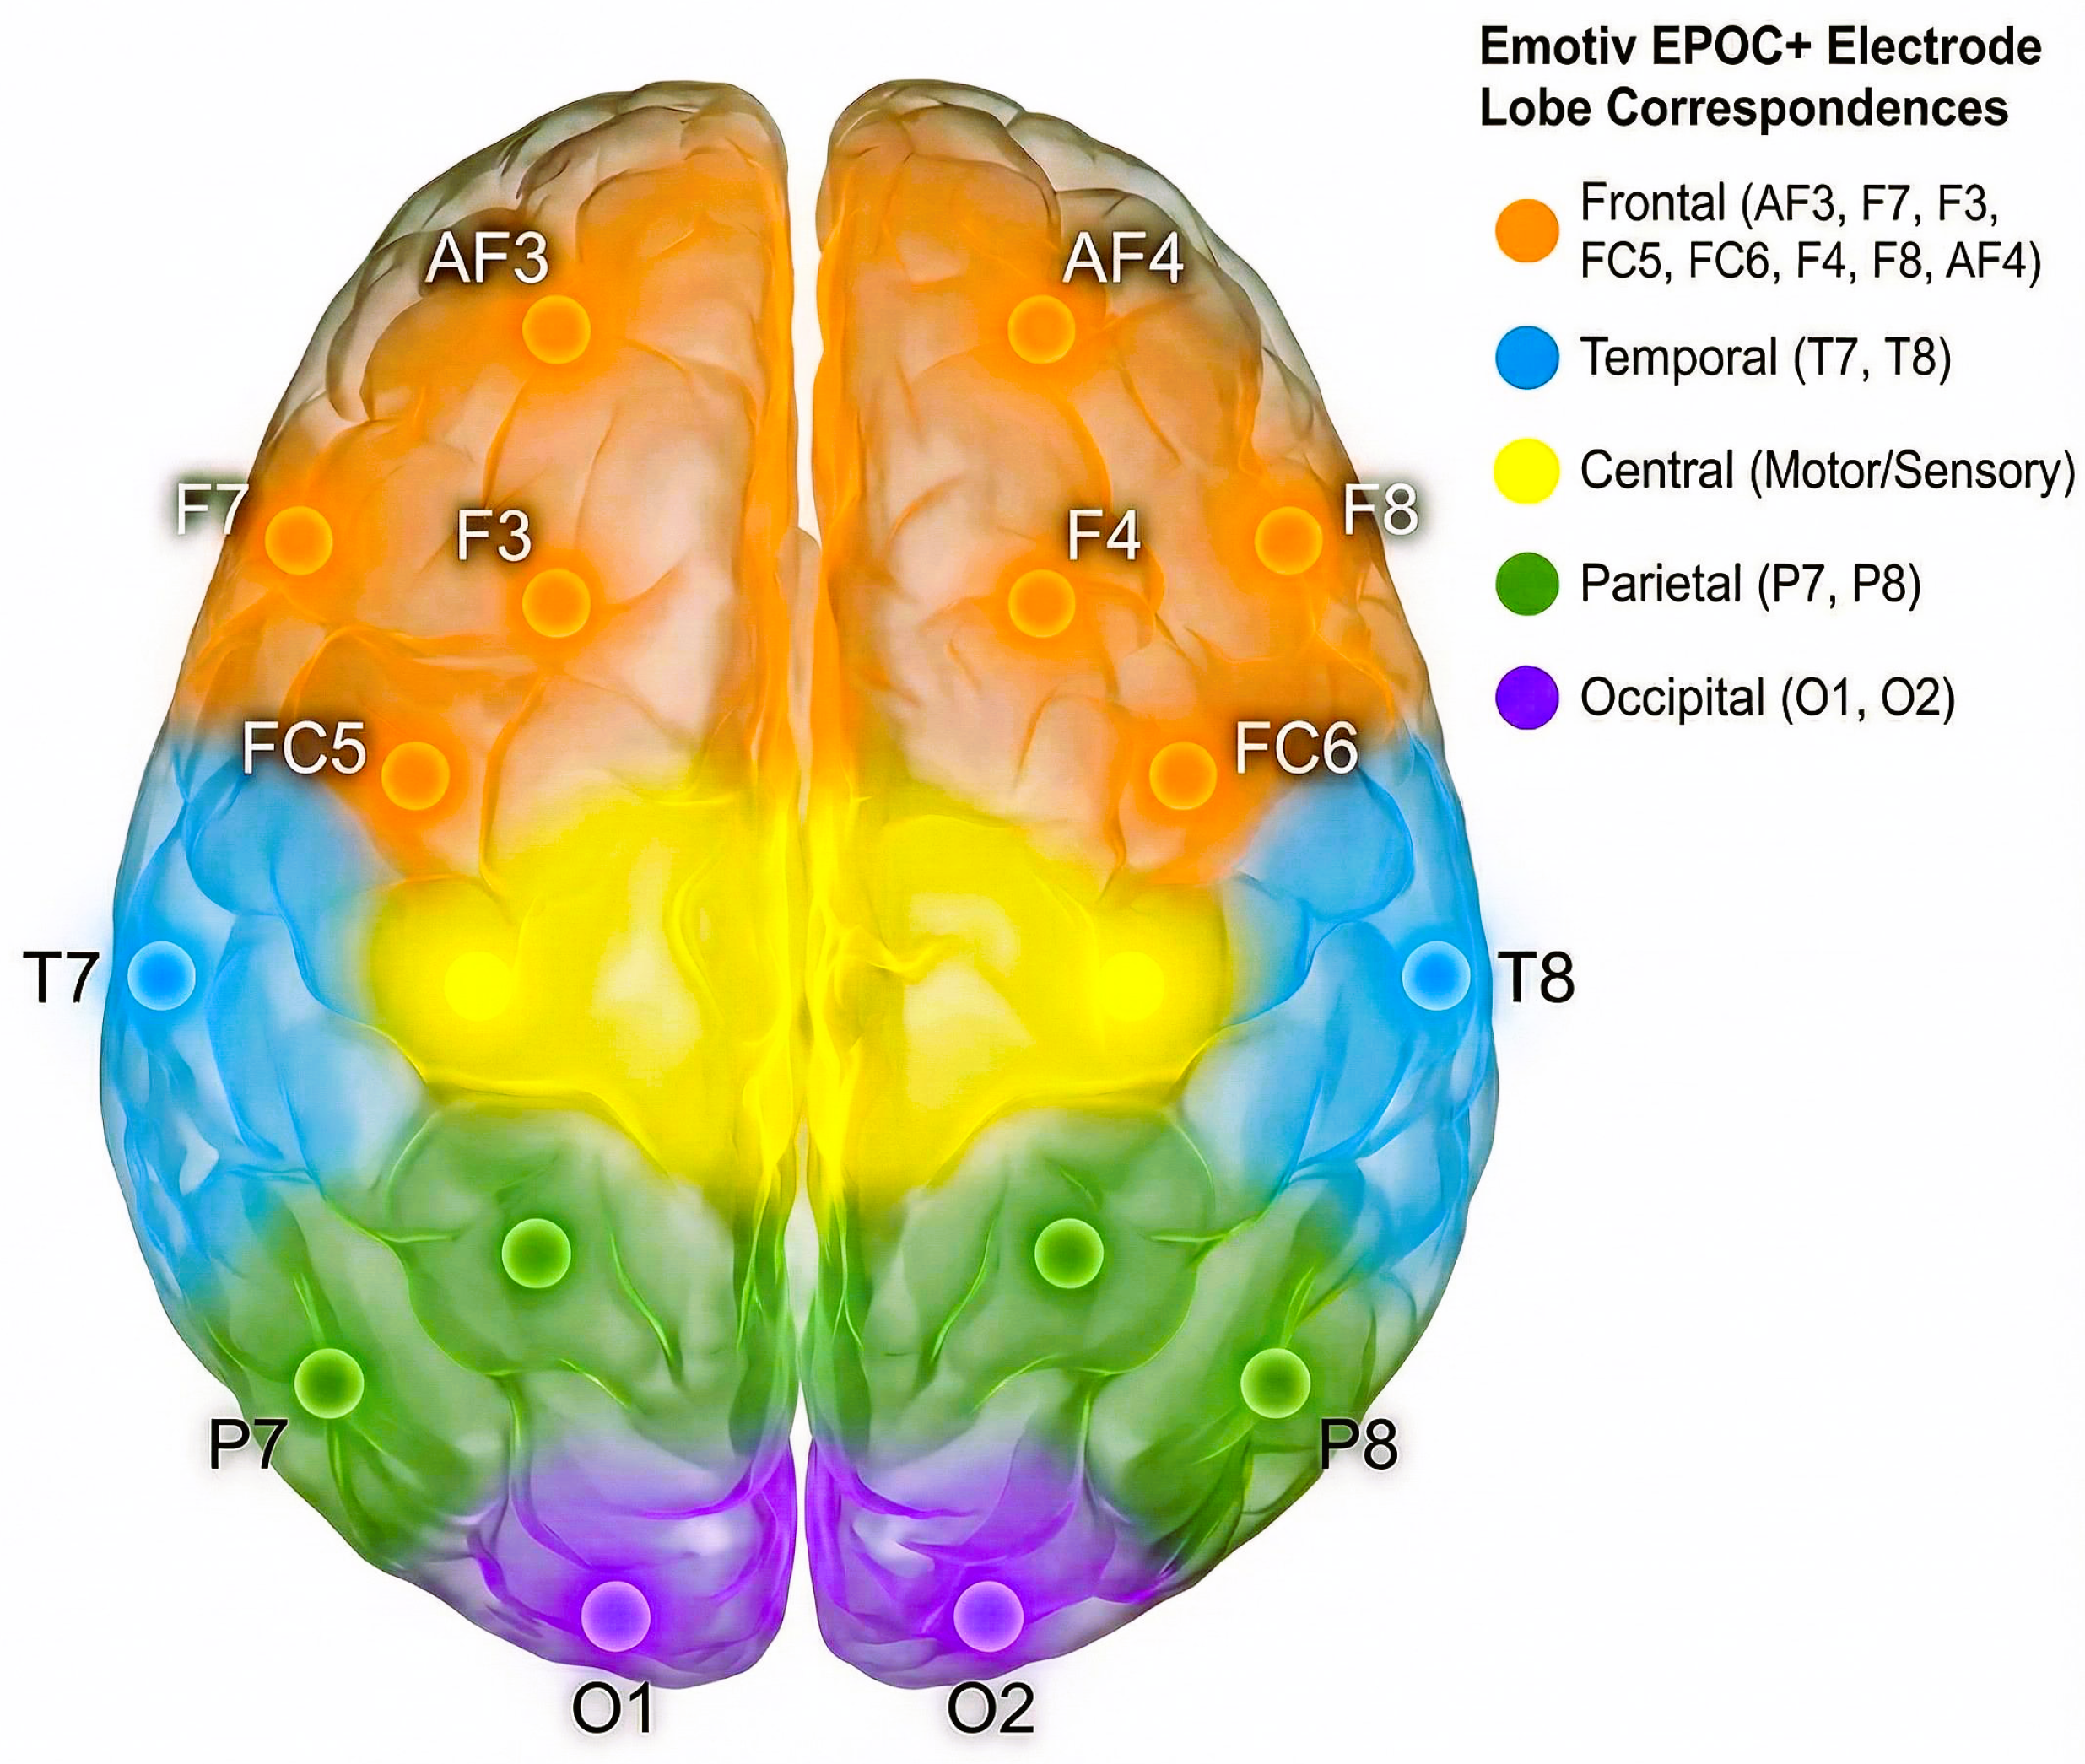
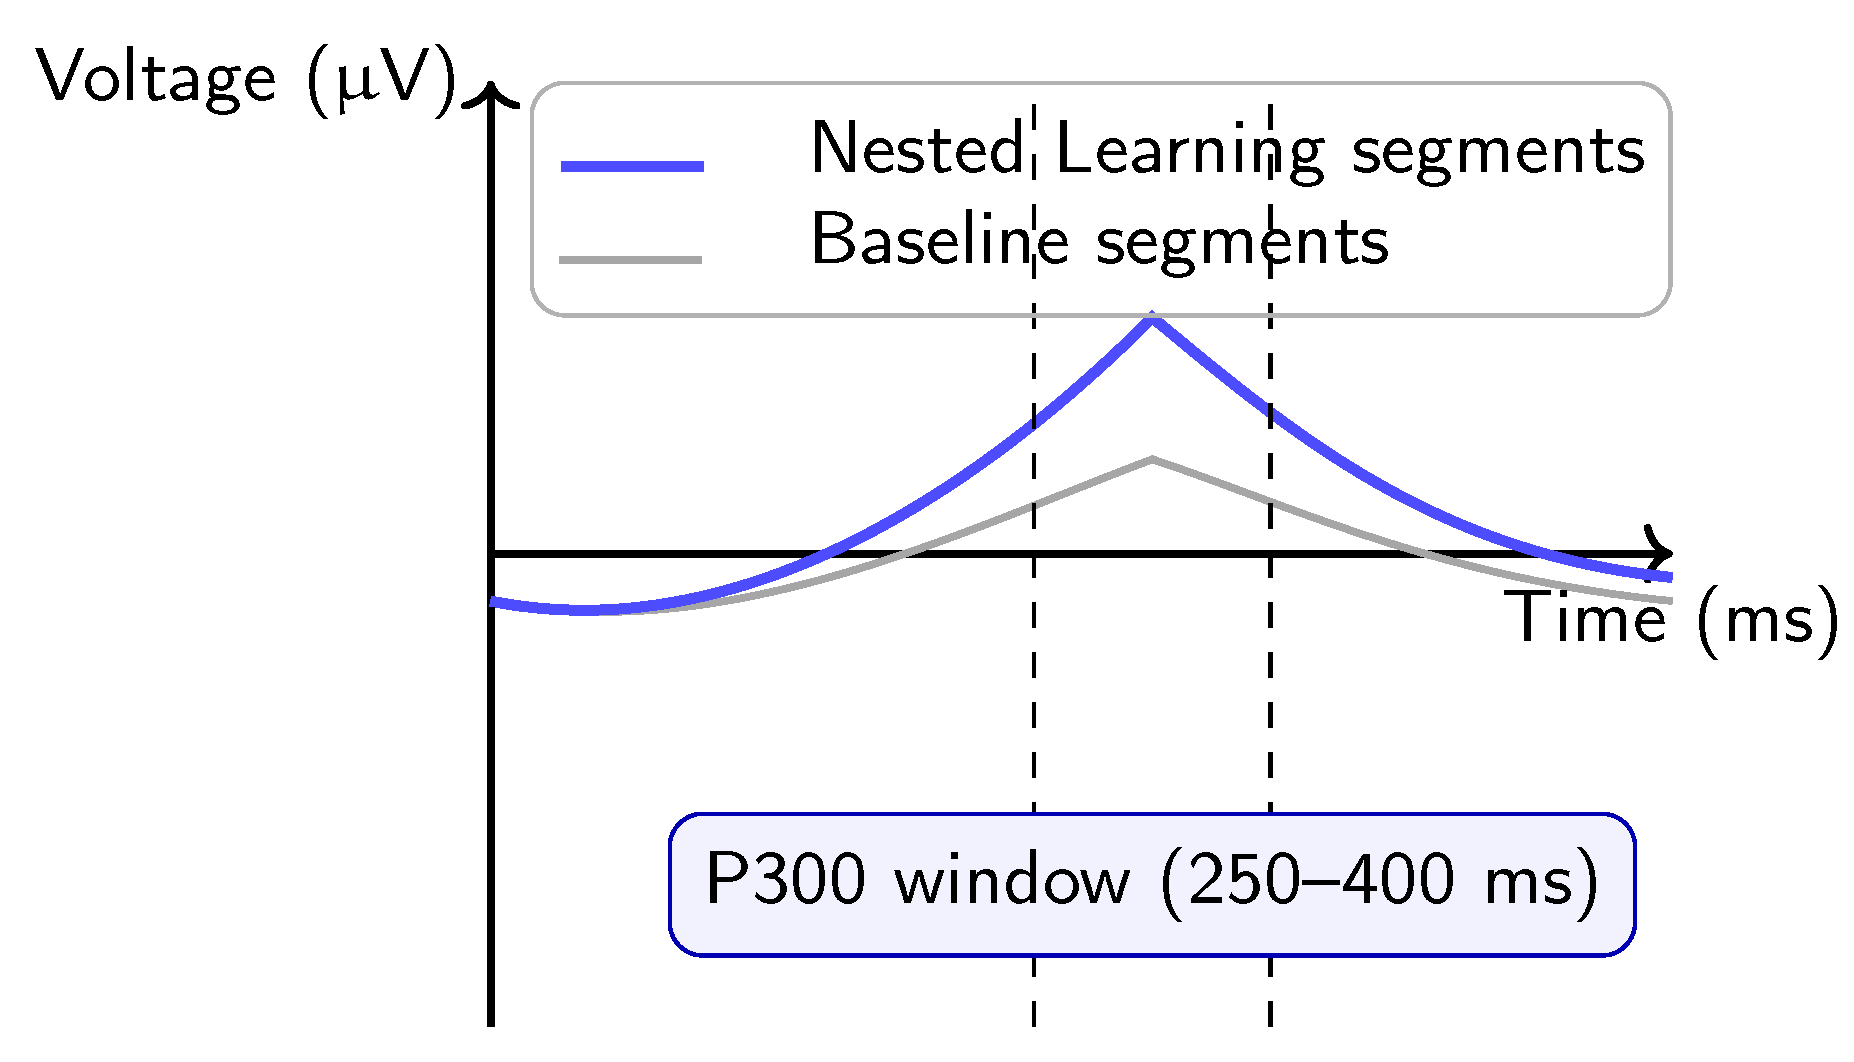
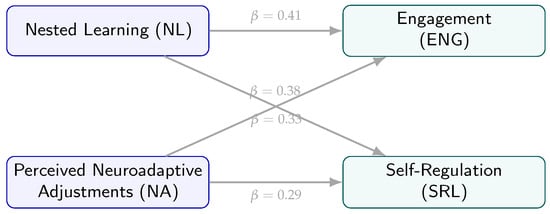
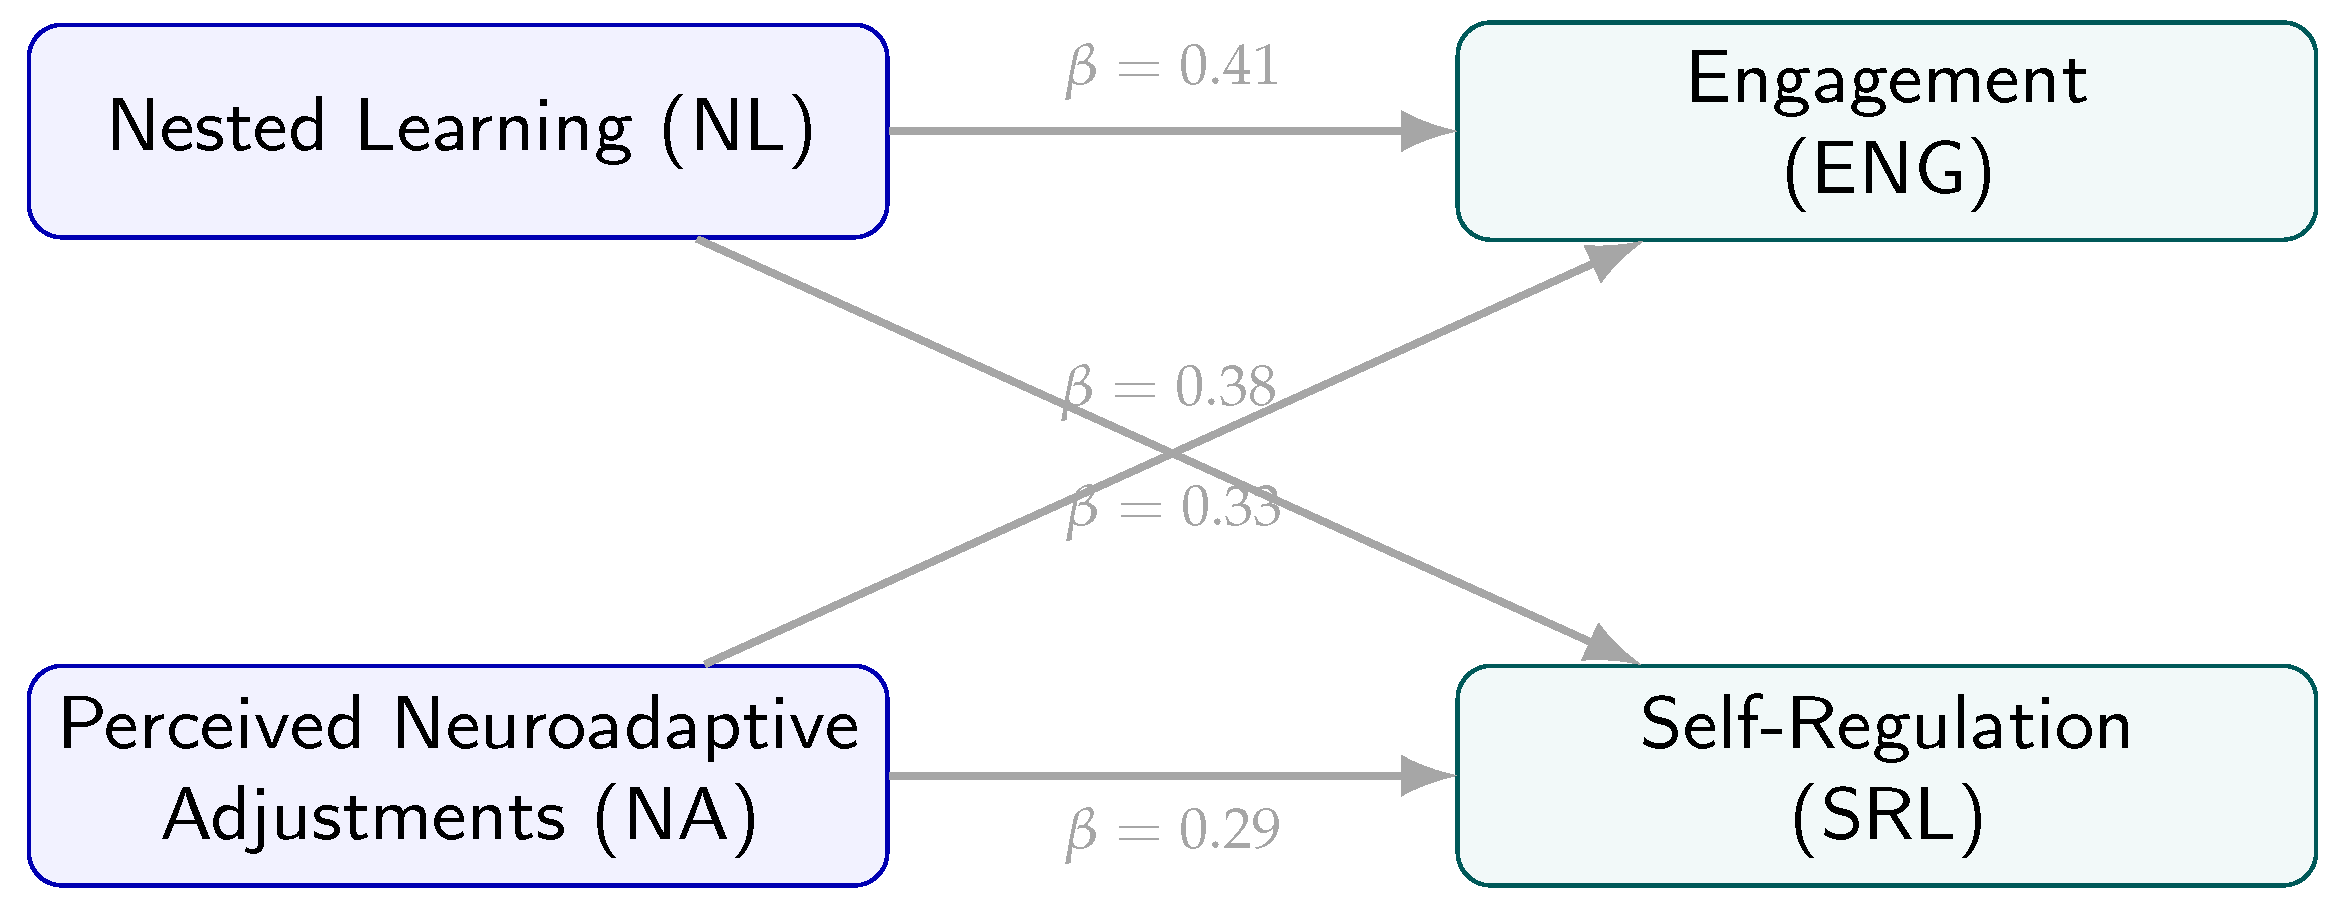
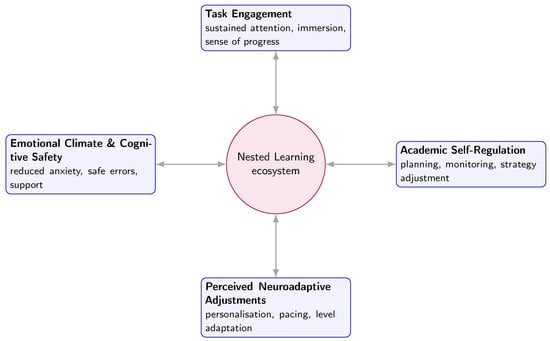
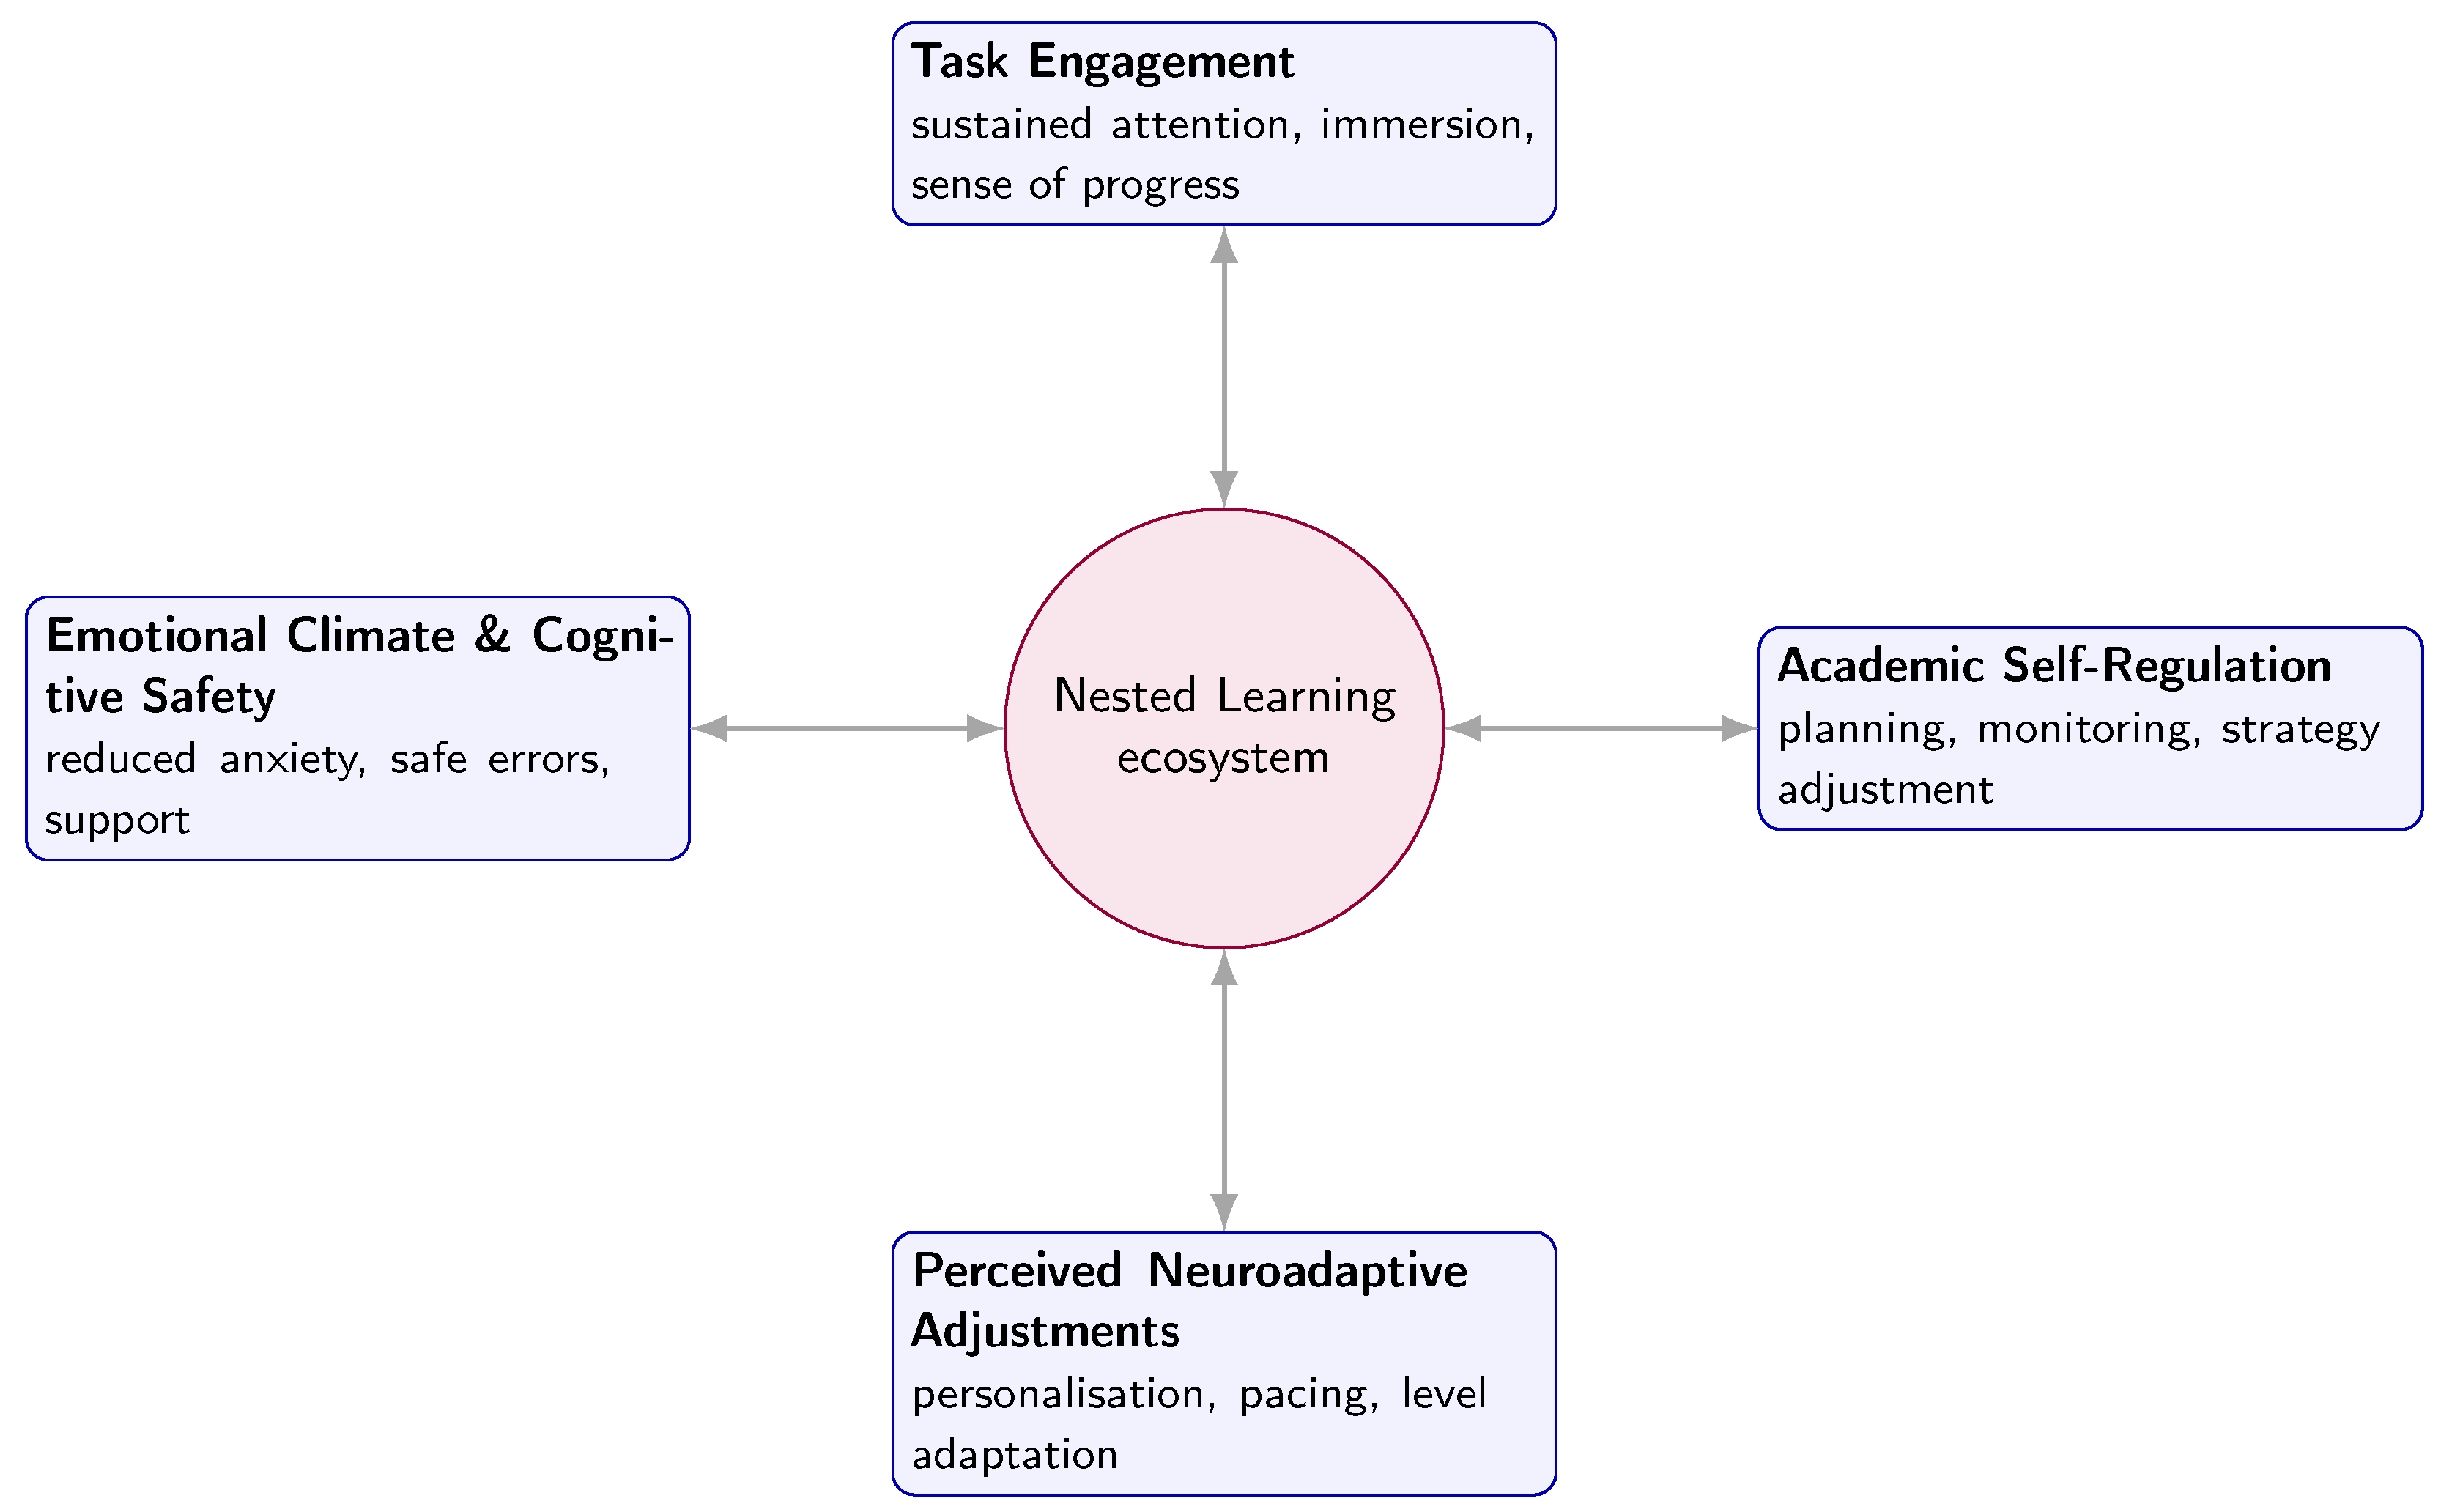

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.