


Abstract
This study develops an integrated electromechanical model of a seed-removing device used in a saw-type cotton gin. The modeled machine unit comprises a squirrel-cage induction motor, an elastic-dissipative belt transmission, a seed-removing tube rigidly connected to a ring gear, planet gears mounted on a fixed carrier, and an auger rigidly connected to the sun gear. The equations of motion were derived using Lagrange’s equations of the second kind. The induction motor was represented by the dynamic characteristic proposed by A.E. Levin, which was selected as a reduced-order model that captures the transient electromagnetic torque response during start-up without requiring the additional electrical parameters of a full direct–quadrature (d–q) axis model, while providing a more realistic transient representation than a static torque–speed characteristic. The moments of inertia of the rotating components were identified experimentally by the acceleration method, and the resulting nonlinear ordinary differential equations were solved by a fourth-order Runge-Kutta scheme. The model reproduces the start-up, transient, and steady-state stages and enables the evaluation of angular velocities, torques, angular accelerations, power demand, and rotational irregularity. Experimental validation was performed for the steady-state rotational speeds of the seed-removing tube and auger and for motor power, whereas the reported transient peak torque and angular acceleration were obtained from the numerical simulation. For the 3 kW, 735 rpm induction motor, the rated torque was 38.98 , whereas the calculated peak starting torque reached 101.63 , corresponding to a starting-torque ratio of 2.61. The transient process lasted approximately 3.5 s, and the maximum motor angular acceleration reached 2988.6 at t = 2.25 s. Within the investigated parameter ranges, the OFAT sensitivity analysis showed that the resistance moment of the seed-removing tube and the inertia of the auger exert the strongest influence on rotational irregularity, whereas the inertia and resistance of the planet gears have a comparatively weak effect. A reduction in the effective torsional stiffness of the belt drive from 17.2 to approximately 10.3 /rad reduced the start-up rotational irregularity of the auger, evaluated over t = 2–4 s, from 0.435 to 0.420 and decreased motor power consumption from about 2.55 to 2.50 kW. The proposed model provides a system-level framework for selecting drive parameters and limiting torsional oscillations in planetary-driven cotton-processing machinery.
1. Introduction
Rotating machine units used in industrial and agricultural equipment increasingly operate under variable technological loads, frequent start-up cycles, and tighter requirements for productivity and energy efficiency. Under these conditions, the motor, transmission, supporting structure, and working members cannot always be treated as dynamically independent components. Elastic deformation, damping, backlash, inertia distribution, and electromagnetic torque variation cause energy exchange between subsystems and may produce transient overloads, torsional oscillations, and non-uniform rotation. These effects are especially important in machines in which the quality and continuity of a technological process depend directly on the rotational stability of several coupled working members.
Recent studies of geared mechanisms have shown that time-varying mesh stiffness, tribological effects, structural flexibility, and load redistribution strongly influence dynamic response [1,2]. Research on controlled transmissions and synchronizing mechanisms has likewise demonstrated that transient motion is governed by the interaction of actuator characteristics, inertia, stiffness, and control laws [3,4,5,6,7]. These findings support the use of system-level models rather than isolated component models when the objective is to predict start-up behaviour, vibration, and power demand.
Integrated modeling of electric motors and mechanical transmissions has become a major direction in rotating machinery research. Electromechanical models of motor–gearbox systems demonstrate that local gear defects, electromagnetic torque pulsations, and mechanical compliance can interact and modify the measured vibration response [8,9,10]. The dynamic response of an induction-motor drive is therefore not fully described by a constant driving torque, particularly during starting and acceleration. Magnetic excitation, voltage distortion, rotor eccentricity, and coupling between lateral and torsional motion may substantially alter the transient load applied to the transmission.
Belt transmissions introduce an additional compliant and dissipative subsystem. Their response depends on belt pretension, nonlinear axial stiffness, transverse vibration, hysteresis, pulley geometry, and operating temperature. Modern analytical, numerical, and experimental studies describe belt drives using distributed-parameter formulations, absolute nodal coordinate methods, viscoelastic models, and data-driven identification [11,12,13,14,15,16,17,18,19,20]. Nevertheless, in many machine-unit models the belt is still reduced to an ideal kinematic ratio or a single linear spring without experimentally supported damping. Such simplification may be acceptable in steady-state kinematic calculations but is insufficient for evaluating start-up oscillations and rotational irregularity.
Planetary transmissions are attractive for compact machines because they provide large speed ratios, coaxial arrangement, and multiple load paths. At the same time, their dynamics are affected by mesh phasing, manufacturing errors, support flexibility, journal-bearing behaviour, and non-uniform load sharing [21,22,23,24,25,26,27,28,29,30,31,32]. Recent models increasingly include flexible components, multi-tooth contact, local faults, and dynamic mesh forces. These works explain the internal behaviour of planetary stages in detail, but most of them do not combine the planetary stage with the induction-motor transient, belt compliance, and a variable technological resistance acting on agricultural working members.
Dynamic models of asynchronous-motor-driven machinery also show that the mechanical response depends on the representation of the motor characteristic. A constant-torque approximation eliminates the most critical part of the transient process: the rapid variation of electromagnetic torque and angular acceleration during starting. Studies of motor vibration, torsional oscillations, tacholess speed estimation, and electromechanical coupling demonstrate the need to include the motor as an active dynamic subsystem rather than as an external constant load [33,34,35,36,37,38,39,40,41,42,43,44,45,46,47].
The technological object considered in this study is the seed-removing device of a saw-type cotton gin. The device continuously removes seeds from the working chamber and therefore affects process stability, energy demand, and the loading of the main machine. Previous studies of cotton-processing machinery have examined the motion of saw cylinders, distributed-parameter working members, vibration diagnostics, machine-vision inspection, and power consumption [48,49,50,51,52,53,54]. Fundamental design and mechanical principles of cotton-processing machines are summarized in classical monographs and dissertations [55,56,57]. These studies establish the technological importance of stable rotation, but the drive is often simplified and does not simultaneously include the induction motor, elastic belt, planetary gear, seed-removing tube, auger, and technological resistance.
The considered machine unit has a specific coupled architecture. The motor drives the seed-removing tube through a belt transmission. The tube carries the ring gear of a planetary stage. Planet gears rotate on a fixed carrier and drive the sun gear, which is rigidly connected to the auger. Consequently, the tube and auger rotate at different speeds, and their motion is linked by both kinematic constraints and elastic-dissipative interactions. The technological resistance acting on the tube is non-uniform, while the auger is subjected to the torque required to transport seeds. The resulting system contains several inertia, stiffness, damping, and load parameters that influence start-up and steady operation.
The literature review reveals three related gaps. First, existing integrated drivetrain models primarily address motor–gearbox coupling, belt-drive dynamics, or the internal dynamics of planetary transmissions, whereas the combined interaction of an induction motor, compliant belt transmission, planetary stage, and process-loaded working members has received limited attention. Second, cotton-gin studies generally focus on individual working members or employ simplified representations of the motor and transmission, which limits their ability to predict start-up electromechanical transients. Third, the combined effects of inertia, transmission compliance, damping, and technological resistance on the rotational irregularity and power demand of a planetary-driven seed-removing device have not been systematically evaluated.
As summarized in Table 1, the novelty of the present study does not lie in the individual motor, belt, or planetary-gear models, which are based on established formulations. The contribution is their system-level integration with the process-loaded working members of the seed-removing device. In particular, the model simultaneously represents the induction-motor transient, compliant belt coupling, planetary kinematics, perforated-tube and auger dynamics, and technological resistance. This enables the propagation of transient electromechanical disturbances from the motor to the working members and their effects on rotational irregularity and power demand to be evaluated within a single model.
Table 1.
Comparison of representative drivetrain models with the present study.
Accordingly, the objective of this study is to develop and analyze an integrated nonlinear electromechanical model of the machine unit “induction motor–belt transmission–planetary gear–seed-removing tube–auger” and to determine parameter combinations that reduce transient loading, power consumption, and rotational irregularity.
The main contributions of this study are as follows: (1) a unified reduced-order electromechanical model coupling the induction motor, compliant belt drive, planetary transmission, and process-loaded working members; (2) analysis of the propagation of start-up torque and speed transients through the complete machine unit; (3) a quantitative assessment of the influence of inertia, transmission, and resistance parameters on rotational irregularity and power demand; and (4) the identification of rational belt-drive parameters that provide a compromise between dynamic performance and energy consumption.
2. System Description
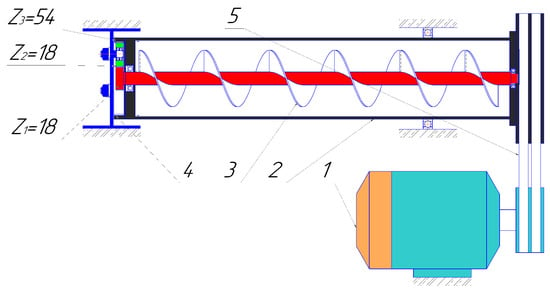
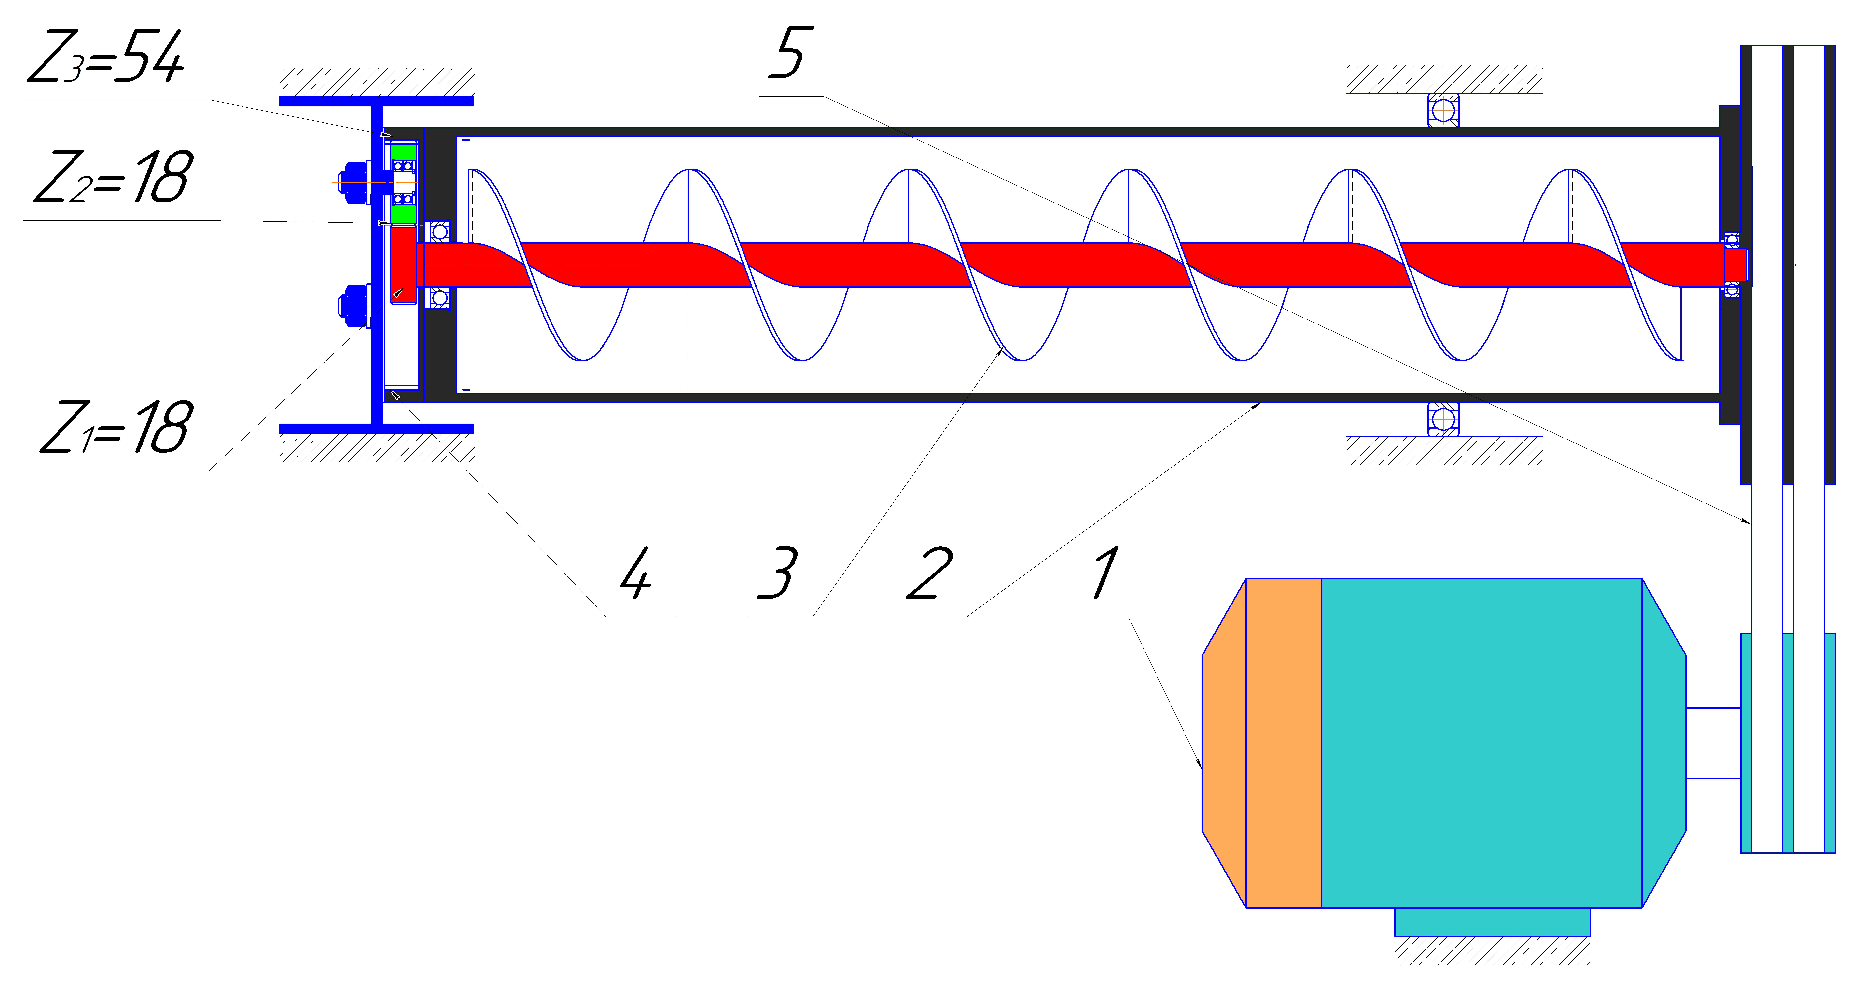
The investigated machine unit (Figure 1) is installed in the seed-removing section of a saw-type cotton gin. It consists of an induction motor, a belt transmission, a perforated cylindrical tube, a planetary gear stage, and a screw auger. The motor pulley transmits rotation to the pulley rigidly connected to the seed-removing tube. The tube is rigidly connected to the ring gear (epicycle) of the planetary transmission. Planet gears are mounted on a stationary carrier, and the sun gear is rigidly connected to the auger shaft. This arrangement produces coordinated rotation of the tube and auger while maintaining different angular velocities.
Figure 1.
Cross-section and principal components of the planetary-driven seed-removing device: (1) electric motor with drive pulley; (2) seed-removing tube; (3) screw auger; (4) ring gear (epicycle); (5) belt transmission.
The seed-removing tube performs two functions: it rotates as a working member interacting with the seed mass and simultaneously acts as the input member of the planetary stage. The auger transports the separated seeds toward the discharge zone. The technological resistance of the tube varies periodically because of non-uniform seed distribution and the repeated interaction of the perforated surface with the material. The auger resistance is determined by seed transport and internal friction.
The use of Lagrange’s equations of the second kind provides a systematic formulation of the force and torque interactions in the system, including the elastic-dissipative properties of the drive components, the moments of inertia of the rotor, tube, and auger, and the resistance torques arising during seed transport. This approach enables the derivation of the equations of motion for subsequent analysis of rotational irregularity, rational selection of drive parameters, and reduction of energy consumption.
where is the ith generalized angular coordinate and is the corresponding angular velocity; T and V are the total kinetic and potential energies of the system, respectively; R is the Rayleigh dissipation function; and is the generalized non-conservative torque associated with . The index i identifies the corresponding rotational degree of freedom of the motor, seed-removing tube, planet gears, or auger.
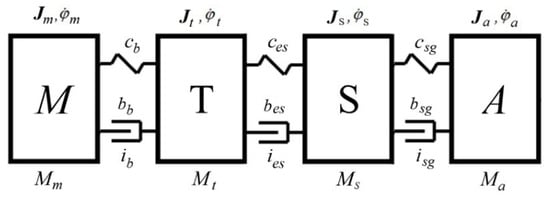
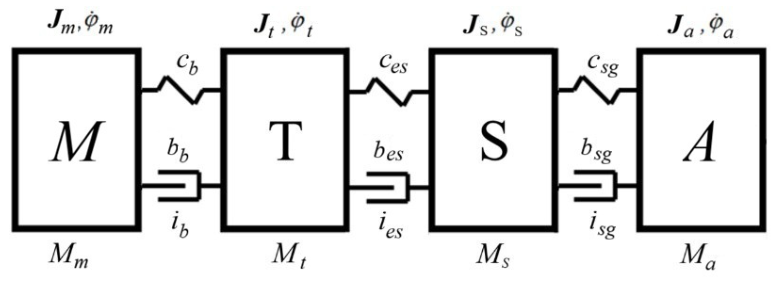
The dynamic model of the machine unit and the kinematic diagram of the seed-removing device are shown in Figure 2. The following notation is used in the model:
Figure 2.
Kinematic and dynamic model of the machine unit.
, and are the moments of inertia of the electric motor, seed-removing tube with epicycle, planet gear, and seed-removing auger with sun gear, respectively, ;
, and are the moments of the loads acting on the rotating shaft of the electric motor, seed-removing tube with epicycle, planet gear, and seed-removing auger with sun gear, ;
, and are the torsional stiffness coefficients of the belt drive and gear meshes (epicycle–planet gear and planet gear–sun gear), ;
, and are the damping coefficients of the belt drive and gear meshes (epicycle–planet gear and planet gear–sun gear), ;
, and are the angular velocities of the electric motor rotor, seed-removing tube with the epicycle, planet gear, and auger with the sun gear, rad/s;
, and are the transmission ratios of the belt and gear drives (epicycle–planet gear and planet gear–sun gear).
The belt-drive pulley diameters are mm on the motor shaft and mm on the tube shaft. Assuming negligible belt slip, the angular velocities of the motor and the seed-removing tube are related by
Thus, the pulley ratio is
The planetary transmission consists of a sun gear with teeth, planet gears with teeth, and a ring gear with teeth. The gears have a module of mm and a standard pressure angle of . The corresponding pitch diameters, calculated as , are mm for the sun gear, mm for each planet gear, and mm for the internal ring gear. The resulting center distance is mm for both the external sun–planet and internal planet–ring meshes. The geometrical compatibility condition for the planetary stage, , is satisfied exactly. The carrier is fixed; therefore, the planet gears rotate about fixed axes. Since the ring gear and the planet gears form an internal gear mesh, their angular velocities have the same sign and satisfy
Thus, the gear ratio is
The planet–sun contact is an external gear mesh; consequently, the planet gear and the sun gear rotate in opposite directions. Since the auger is rigidly connected to the sun gear,
Thus, the gear ratio is
Combining the two planetary-gear relations gives
Accordingly, taking the belt transmission into account,
The signs in the gear ratios indicate the relative directions of rotation. In the reduced dynamic model (Figure 2), the actual kinematic relationships are retained through the transmission ratios appearing in the elastic and dissipative deformation terms. The four generalized coordinates are the angular displacements of the motor rotor, tube with ring gear, representative planet gear, and auger with sun gear.
Positive angular coordinates and angular velocities are defined in the direction of rotation of the corresponding shaft. Throughout the model, the transmission ratio between two rotating members i and j is defined as
A positive transmission ratio () denotes rotation in the same direction, whereas a negative ratio () denotes opposite directions of rotation. This sign convention is retained throughout the kinematic and dynamic equations of the belt and planetary transmissions.
The supports are assumed sufficiently stiff relative to the torsional compliance of the belt and gear contacts. Therefore, support elasticity and housing vibration are not included in the present torsional model. The principal sources of compliance are represented by the belt stiffness , ring–planet mesh stiffness , and planet–sun mesh stiffness . Energy dissipation is represented by the corresponding coefficients , , and .
The compliance terms introduced in the lumped-parameter model represent equivalent torsional mesh stiffnesses referred to the pitch circles of the corresponding gears rather than localized linear tooth-contact stiffnesses. Thus, the tooth-contact deformation is not modeled as an independent translational degree of freedom. Instead, the elastic deformation of each gear mesh is represented by the relative angular displacement of the mating gears, taking the corresponding transmission ratio and direction of rotation into account. If the gear-mesh stiffness is initially expressed as an equivalent linear contact stiffness (), its corresponding torsional stiffness referred to a gear pitch circle is
where is the pitch radius. Accordingly, all gear-mesh stiffness coefficients used in the equations of motion are expressed in . The same interpretation is used for the elastic elements shown in Figure 2.
The present lumped-parameter model represents mechanical dissipation through equivalent viscous damping and experimentally determined resistance torques. This formulation is appropriate for describing the overall transient and steady-state dynamics considered in this study, but it does not explicitly reproduce static breakaway friction or the velocity-dependent friction behavior at very low rotational speeds. More detailed friction formulations, including Coulomb and Stribeck models, can improve the representation of mechanical systems during start-up, velocity reversal, and low-speed motion [58].
Incorporating this nonlinear friction model into the present system would require separate experimental identification of the friction parameters for the bearings and gear contacts. Since these parameters were not independently measured in the present study, introducing them would add unverified parameters to the model. Therefore, the present analysis retains the experimentally based equivalent resistance and damping representation, while nonlinear Coulomb–Stribeck friction is identified as an extension for improving the prediction of breakaway torque and the very early start-up response.
3. Mathematical Model
3.1. Generalized Coordinates and Energy Expressions
The generalized coordinates are the angular displacements of the four rotating elements: the motor rotor, seed-removing tube with ring gear, representative planet gear, and auger with sun gear. The corresponding generalized angular velocities are , and .
These coordinates describe the dynamic behavior of the machine unit and enable the derivation of the equations of motion while accounting for the elastic and damping properties of the transmission.
The kinetic energy of the seed-removing device is expressed as follows:
The elastic potential energy is written in terms of relative torsional deformations referred to the corresponding transmission members:
The Rayleigh dissipation function is
The signs of the transmission ratios in Equations (12) and (13) follow the adopted kinematic convention. In particular, the external mesh between a planet gear and the sun gear results in a negative transmission ratio, since the two gears rotate in opposite directions. The relative angular displacement associated with the elastic deformation of the mesh is written as
and the corresponding relative angular velocity is
For the present gear set, and hence . Consequently,
Accordingly, the corresponding elastic-energy and Rayleigh-dissipation terms take the form
where and are the equivalent torsional stiffness and damping coefficients of the corresponding mesh. Therefore, the negative transmission ratio affects only the kinematic combination of the generalized coordinates and velocities; it does not imply negative stiffness or negative damping. The squared form of the potential-energy and Rayleigh dissipation terms ensures non-negative stored energy and non-negative energy dissipation.
The terms required to derive the equations of motion are obtained as follows:
1. The partial derivatives of the potential energy with respect to the generalized coordinates are:
2. The partial derivatives of the Rayleigh dissipation function with respect to the generalized velocities are:
3. The partial derivatives of the kinetic energy with respect to the generalized velocities are:
4. Their time derivatives are:
5. The generalized torques are:
Substituting Equations (19)–(23) into Lagrange’s equations of the second kind, Equation (1), yields the following system of differential equations of motion:
The model is nonlinear because the motor torque depends on rotor speed and the technological resistance may vary with time and angular velocity.
3.2. Induction-Motor Model
A dynamic characteristic of the squirrel-cage induction motor is used instead of a constant driving torque. In the adopted reduced-order Levin representation, the electromagnetic torque and the auxiliary electromagnetic state variable evolve according to [59]
Here, is an auxiliary electromagnetic state variable of the reduced-order Levin model that represents the internal electromagnetic state governing the transient build-up and decay of the motor torque. It is not treated as an independently measured mechanical quantity; rather, together with , it accounts for the finite electromagnetic response time of the induction motor during changes in slip and rotor speed. is the generalized angular coordinate of the motor rotor, and is its mechanical angular velocity (rad/s). The coupling term represents the electrical slip angular frequency and couples the mechanical rotor speed to the electromagnetic torque dynamics. Furthermore, is the electromagnetic time constant, is the critical slip, P is the number of pole pairs, is the critical torque, and is the electrical angular frequency. The adopted motor is a 4A112M8U3 squirrel-cage induction motor with a rated power of 3.0 kW, rated speed of 735 rpm, rated torque of 38.98 , critical torque of 77.95 , supply frequency of 50 Hz, efficiency of 0.83, power factor of 0.74, four pole pairs, and nominal slip of 0.02.
The critical slip was calculated rather than taken directly from the motor nameplate data. Using the nominal slip and the critical-to-rated torque ratio , the critical slip was determined from the Kloss torque–slip relation as
3.3. Technological Resistance
The technological resistance acting on the seed-removing tube was determined experimentally from the electrical loading of the induction motor during operation of the seed-removing device. The motor current was measured under the investigated operating conditions, and the corresponding electrical power was evaluated using the motor supply parameters. For a three-phase induction motor, the active input power can be expressed as
where U is the line voltage, I is the measured line current, and is the motor power factor. The corresponding mechanical power transmitted by the motor was estimated as
where is the motor efficiency.
The equivalent resistance torque referred to the perforated tube shaft was then determined from the power–torque relationship,
where is the mechanical power component associated with the technological resistance of the seed-removing tube and is its angular velocity. The experimentally determined limiting values were
These values correspond to the lower and upper resistance levels observed from the motor-current measurements under the investigated operating conditions. They were used to define the mean and periodic components of the technological resistance as
and
Accordingly, the resistance torque acting on the seed-removing tube is represented as the sum of a mean component and a periodic component:
For the baseline calculation,
The resistance associated with seed transport by the auger was determined using the same experimental principle. The change in the motor electrical loading associated with operation of the auger under seed transport conditions was evaluated from the measured motor current. After accounting for the motor operating parameters, the corresponding mechanical power required for seed transport was determined as
The equivalent average resistance torque acting on the auger was calculated from the power–torque relationship
At the nominal operating condition, the auger speed corresponding to the kinematic relationship of the planetary transmission is
and therefore
Thus,
Because three identical planet gears share the load transmitted between the ring and sun gears, the average load associated with one planet gear was represented by the equivalent torque
Thus, the technological resistance parameters used in the dynamic model were not arbitrary fitting coefficients; they were derived from experimentally observed changes in the electrical loading of the drive and subsequently converted into equivalent mechanical resistance torques.
3.4. Belt and Gear Damping
The effective torsional stiffness of the belt drive is determined according to [15,16,17]:
where is the elastic modulus; is the coefficient accounting for belt pretension under normal operating conditions; F is the belt cross-sectional area, ; m is the pulley radius; and is the belt length, m.
For the investigated B-section belt,
The belt-drive damping coefficient [18,19,20] is determined as follows:
where is the damping coefficient adopted for the transmission mechanism within the range , and is the oscillation period, s.
For the investigated B-section belt, . Equivalent expressions are used for the two gear meshes.
4. Experimental Methodology
4.1. Identification of Moments of Inertia
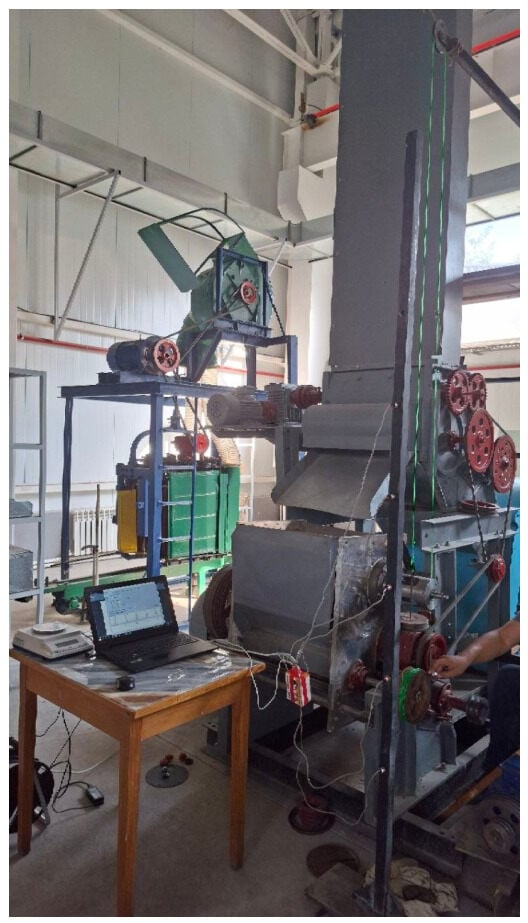
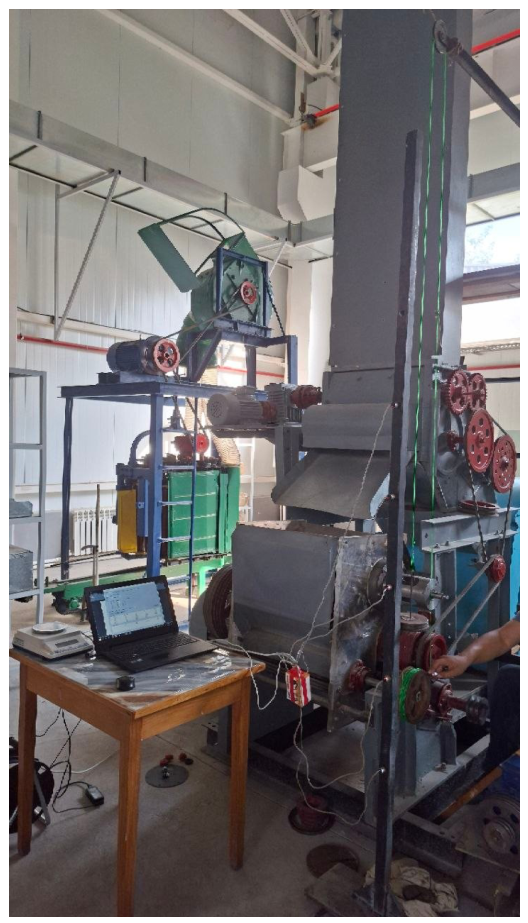
The moments of inertia of the motor rotor and the rotating working members were determined experimentally by the acceleration method. Each body was mounted on its operating bearings. A thread was wound around a pulley of known radius, passed over a guide pulley, and loaded by a suspended mass. The load was raised through a known height and released. The descent time was measured from video recordings. Two or more load levels were used to separate the effect of bearing resistance from the inertia term (Figure 3).
Figure 3.
Experimental arrangement for identifying the moments of inertia by the acceleration method.
This method enables accurate experimental determination of the moments of inertia while accounting for the design features of the device, including the actual mass distribution and bearing-support effects
where g = 9.81 is the acceleration due to gravity; is the gravitational force, N; r is the pulley radius, m; m is the suspended mass, kg; t is the load descent time, s; and h is the descent height, m.
To determine h and , an ESP32 DevKit V1 (ESP32-WROOM-32) microcontroller (Shenzhen Chengsuchuang Technology Co., Ltd., Shenzhen, China) and five E3F-DS30C4 photoelectric sensors (Yuanhuang Electric Technology Co., Ltd., Zhejiang, China) were used. The sensors were powered by a 12 V power supply, and a USB cable was used to transfer data from the ESP32 to the computer. The distances between the E3F-DS30C4 photoelectric sensors were 300 mm. The five E3F-DS30C4 photoelectric sensors defined four measurement intervals along the falling-mass path. Their response time of less than 2 ms and switching frequency of up to 300 Hz provided sufficient temporal resolution for determining the descent times and corresponding accelerations (Figure 3).
The experiments yielded the following moments of inertia: for the motor rotor with pulley (Table 2), for the seed-removing tube with epicycle and pulleys (Table 3), for one planet gear (Table 4), and for the auger with sun gear and pulleys (Table 5). In addition, the equivalent moment of inertia of the complete seed-removing device, referred to the seed-removing tube shaft, was determined as (Table 6).
Table 2.
Experimental determination of the rotational inertia of the electric motor with pulley ( m; ).
Table 3.
Experimental determination of the rotational inertia of the seed-removing tube ( m; ).
Table 4.
Experimental determination of the rotational inertia of one planet gear ( m; ).
Table 5.
Experimental determination of the rotational inertia of the auger ( m; ).
Table 6.
Experimental determination of the equivalent rotational inertia of the seed-removal device ( m; ).
The experimental results demonstrated good repeatability for all investigated components, with coefficients of variation ranging from 0.0517% to 1.68%. Based on the mean experimental values, the rotational inertias adopted in the dynamic model were for the electric motor with pulley, for the seed-removing tube, for one planet gear, and for the auger. The equivalent rotational inertia of the complete seed-removing device, referred to the seed-removing tube shaft, was . The low coefficients of variation confirm the repeatability of the experimental determination of the rotational inertia parameters used in the dynamic model.
4.2. Numerical Solution
The coupled second-order differential equations and the two first-order motor equations were transformed into a first-order state-space system. The state vector contained four angular displacements, four angular velocities, the motor torque, and the auxiliary electromagnetic variable. The resulting system was integrated using the classical fourth-order Runge–Kutta (RK4) method with a fixed time step of s, which was used consistently in all transient and parametric calculations. The initial angular velocities were set to zero, and the initial electromagnetic state corresponded to the connection of the unloaded motor to the power supply. At , the motor was assumed to be at rest and disconnected immediately prior to energization; therefore, the initial conditions were and , together with . The supply voltage was applied at , after which and evolved according to the Levin dynamic motor equations.
The time step was selected so that further reduction did not materially change peak torque, settling time, or steady-state angular velocities. Simulations were continued until all working members reached a quasi-steady regime. For each case, the following response indicators were calculated: peak electromagnetic torque; maximum angular acceleration; transient duration; mean angular velocity; rotational irregularity; and mean motor power.
where , , and denote the maximum, minimum, and mean angular velocities, respectively. In this study, rotational irregularity is a time-window-dependent metric and is therefore evaluated separately for the start-up transient and steady-state operation; values obtained for these two stages should not be interpreted as directly equivalent operating indicators. The interval t = 2–4 s corresponds to the start-up transient and was used to characterize the maximum transient rotational irregularity. Cotton feeding begins at s; therefore, the rotational irregularity representative of normal cotton-ginning operation was evaluated separately over the steady-state interval t = 17–20 s, after the disturbance caused by the introduction of the technological load had decayed. The maximum, minimum, and mean angular velocities used in Equation (42) were calculated only from the data within the corresponding time interval and were not taken over the entire simulation period.
4.3. Parameter-Variation Plan
A one-factor-at-a-time sensitivity study was performed around the baseline configuration. The effective stiffness and damping of the belt drive, the resistance moments of the tube and auger, and the moments of inertia of the four rotating bodies were varied over the ranges used in the original numerical experiments. The purpose of the OFAT sensitivity analysis was to physically rank the investigated parameters and identify practical directions for rational parameter selection within the considered parameter ranges (Table 7). Parameter interactions were not evaluated; therefore, the results should be interpreted as local sensitivity-based design guidance rather than as a formal multivariable optimization.
Table 7.
Principal parameters used in the baseline simulation.
4.4. Use of Generative Artificial Intelligence
Generative artificial intelligence was used during manuscript preparation to assist with English-language editing, improvement of academic style, clarification of technical descriptions, and refinement of the presentation of the mathematical and methodological content. The tool was not used to generate experimental data, perform numerical simulations, calculate the reported results, or replace the authors’ scientific interpretation. All AI-assisted text was critically reviewed, verified, and revised by the authors, who take full responsibility for the accuracy and integrity of the manuscript.
5. Results
5.1. Motor Start-Up and Transient Response
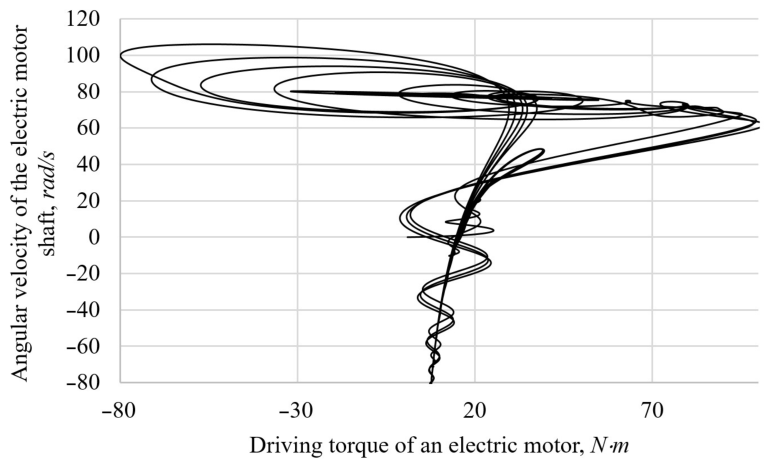
The simulated motor characteristic exhibits the three expected stages: a rapid torque rise immediately after connection to the supply, acceleration with a gradual torque decrease, and stabilization near the operating point. The electromagnetic torque varies between approximately and (Figure 4). The positive maximum is 2.61 times the rated torque of 38.98 , confirming that a constant nominal-torque representation would substantially underestimate the transient loading of the belt and planetary transmission.
Figure 4.
Electromagnetic torque versus motor angular velocity during start-up.
During motor start-up, the electromagnetic torque exhibits transient oscillations and temporarily reaches N · m (Figure 4). This behavior is caused by the rapidly varying rotor slip and the transient interaction between the electromagnetic dynamics and the inertia of the mechanical system. During short intervals, the electromagnetic torque acts opposite to the direction of rotation, producing temporary braking without reversing the motor. As the motor approaches its operating speed, these oscillations decay and the torque stabilizes.
The principal motor transient lasts approximately 3.5 s. The motor angular acceleration was calculated by numerical differentiation of the simulated angular velocity using the central finite-difference approximation,
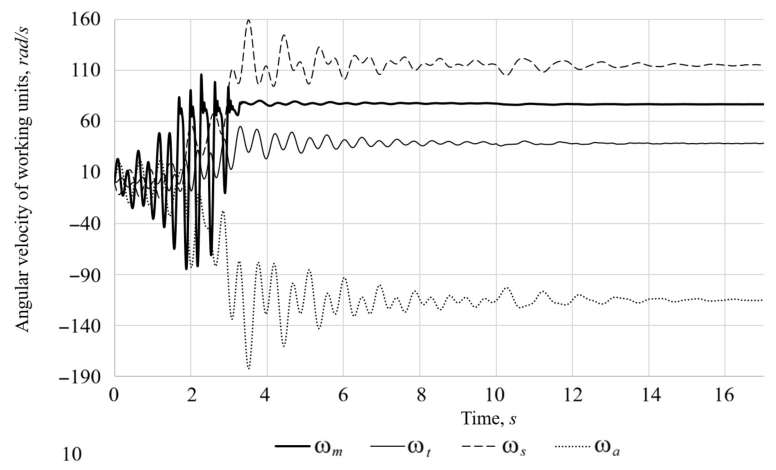
where s is the integration time step. The maximum angular acceleration reaches 2988.6 at s (Figure 5). This short-duration acceleration peak is transmitted through the compliant belt and excites torsional oscillations of the tube, planet gear, and auger. Because the working members have different inertias and are connected through different stiffness and damping parameters, their velocity oscillations are phase-shifted and decay at different rates.
Figure 5.
Time histories of the angular velocities of the motor, tube, planet gear, and auger.
The seed-removing tube reaches a maximum angular acceleration of approximately 107.1 rad/s2, and its broader mechanical transient persists for about 7 s. The longer settling time of the tube compared with the motor reflects the compliant belt connection and the additional energy exchange with the planetary stage and auger. The calculated mean motor power during operation is approximately 2.5 kW (Figure 6).
Figure 6.
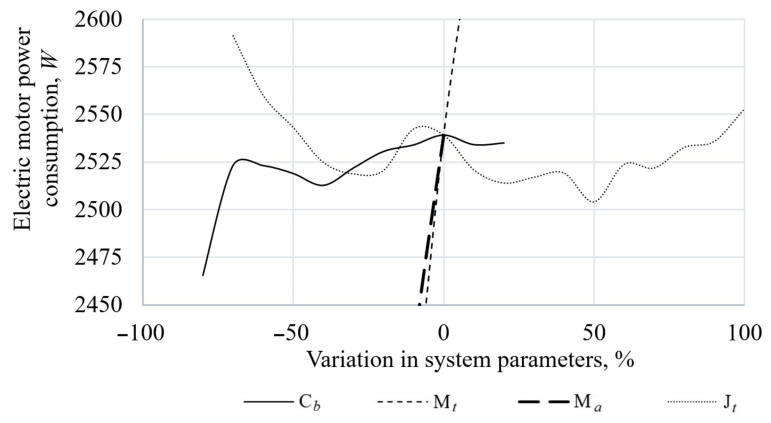
Sensitivity of motor power to the model parameters.
5.2. Steady-State Speeds and Rotational Irregularity
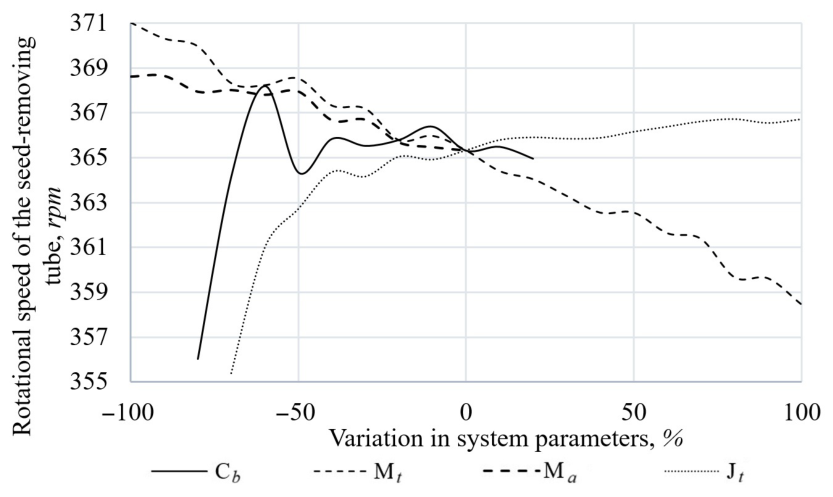
Under steady-state operation, the model predicts coordinated rotation consistent with the imposed belt and planetary ratios. The auger speed lies near 1075.5 rpm for the baseline resistance, while the tube speed varies within approximately 355–371 rpm over the investigated parameter range. The maximum transient rotational irregularity of the auger, evaluated over the start-up interval t = 2–4 s, is approximately 0.42–0.44, depending on the selected belt and load parameters. The rotational irregularity during normal cotton-ginning operation was evaluated separately over t = 17–20 s. Accordingly, the start-up and steady-state irregularity values characterize different dynamic stages and should be compared only within their respective evaluation windows.
The calculated response confirms that elastic-dissipative coupling is not merely a numerical correction to the kinematic ratios. It determines the amplitude and decay of speed oscillations and therefore changes both the instantaneous torque demand and the average motor power. The belt drive has the strongest controllable influence because it is the first compliant element excited by the motor start-up torque.
5.3. Sensitivity to Drive and Load Parameters
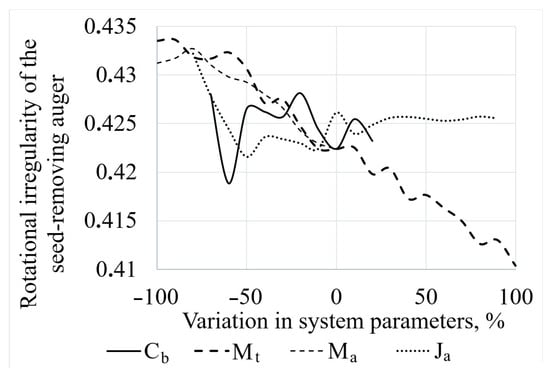
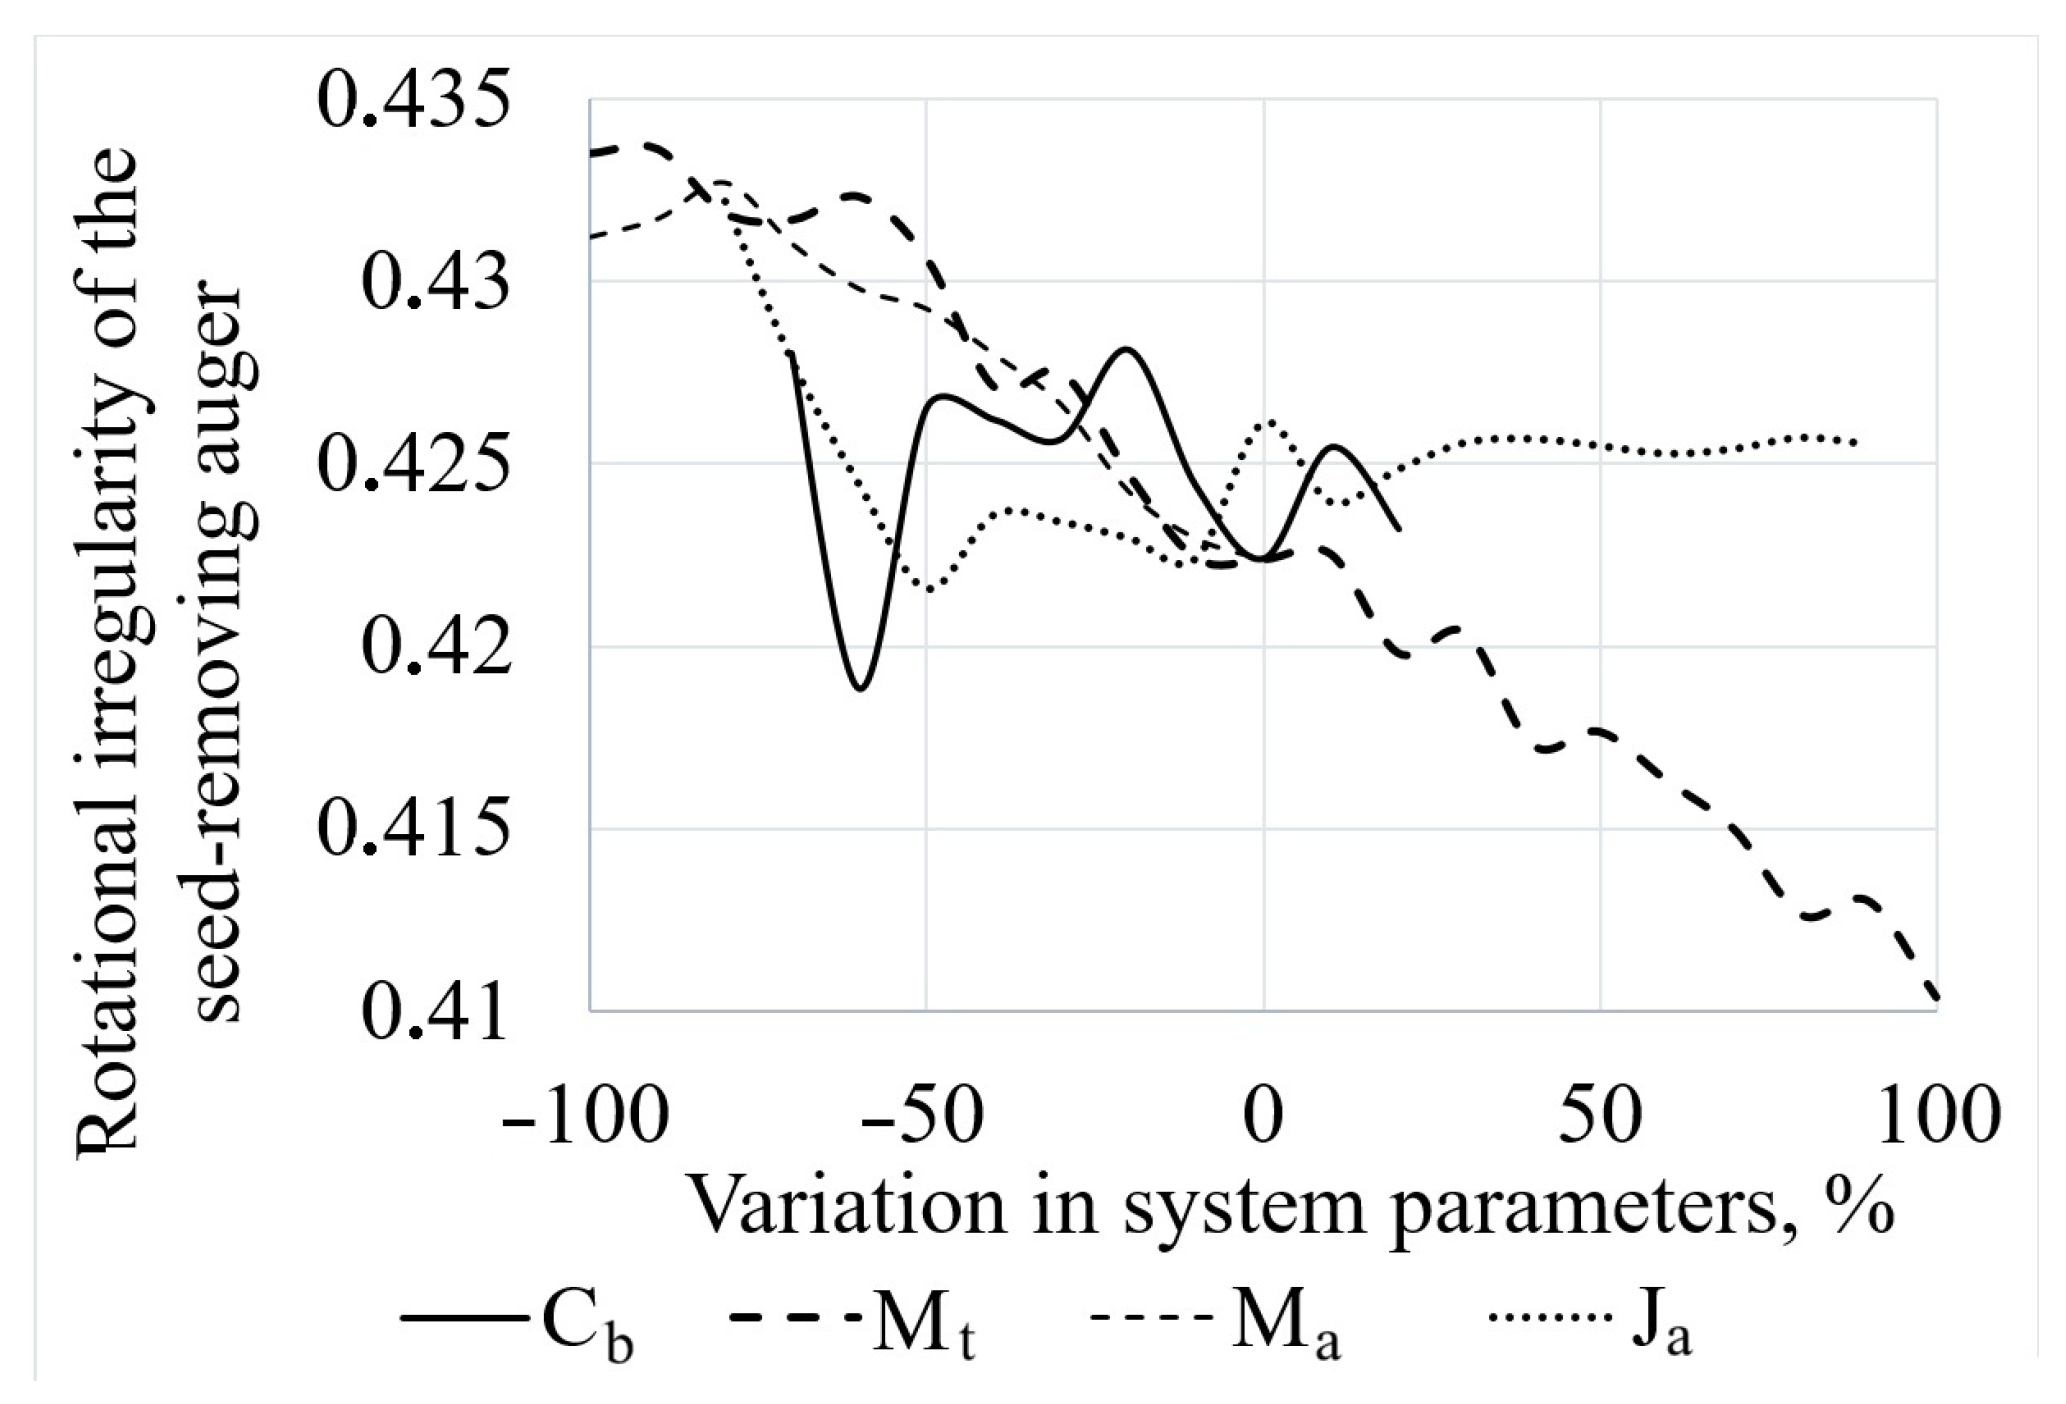
Within the investigated parameter ranges, the resistance moment of the seed-removing tube and the moment of inertia of the auger have the strongest effect on auger rotational irregularity. The effect of the planet-gear inertia and planet resistance is comparatively small within these ranges. This local sensitivity ranking is physically reasonable: the tube resistance acts directly at the input member of the planetary stage, whereas the auger inertia is located at the output and stores a substantial part of the oscillatory kinetic energy.
Over the investigated variations, the following changes in the calculated irregularity were obtained: variations associated with the tube resistance produced values around 0.4220–0.4256; changes in motor inertia gave approximately 0.4224–0.4263; changes in tube inertia gave 0.4222–0.4279; changes in planet-gear inertia gave 0.4218–0.4230; and changes in auger inertia gave 0.4216–0.4322 (Figure 7). Within the investigated parameter ranges, the largest relative change, about 2.46%, corresponded to the auger inertia.
Figure 7.
Sensitivity of auger rotational irregularity to the model parameters.
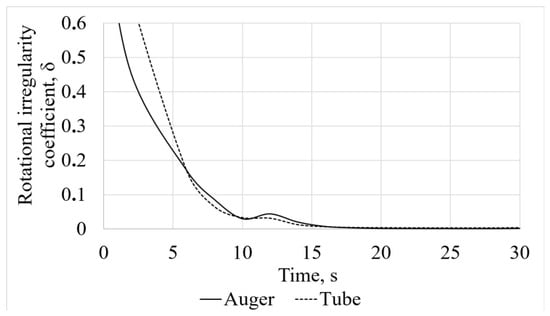
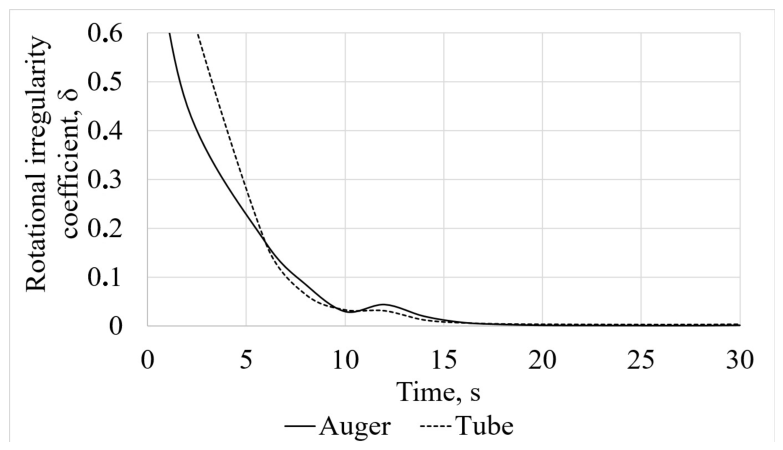
The rotational irregularity of the perforated tube and auger was evaluated over successive 2 s intervals throughout the simulation. Figure 8 therefore illustrates the decay of speed fluctuations of both working members from the initial start-up stage to the quasi-steady operating regime. The interval t = 2–4 s was considered separately as representative of the most pronounced start-up transient and was subsequently used in the parameter-variation analysis.
Figure 8.
Evolution of the rotational irregularity of the seed-removing tube and auger, calculated over successive 2 s intervals during the simulated transient and steady-state response.
As the auger resistance moment increased from the lower bound of the investigated range toward the baseline value, the auger speed decreased from approximately 1085.3 to 1075.5 rpm (Figure 9). Simultaneous variation of the belt properties and the tube and auger resistance moments produced motor power values of approximately 2.45–2.60 kW. The tube speed remained within 355–371 rpm when the belt properties, tube resistance, and tube inertia were varied.
Figure 9.
Influence of the resistance moments and inertia parameters on tube and auger speeds.
The high rotational irregularity observed during approximately t = 2–4 s corresponds to the start-up transient of the drive system without cotton feeding. During subsequent acceleration, the irregularity of both the seed-removing tube and auger decreases rapidly. Cotton feeding starts at s, producing a small temporary increase in rotational irregularity due to the applied technological load, which is more pronounced for the auger. This disturbance is rapidly damped, and the irregularity approaches zero at approximately t = 15–17 s. Thus, the previously reported values of – characterize only the start-up transient and are not representative of the steady-state cotton-ginning operation.
The one-factor-at-a-time sensitivity analysis is summarized in Table 8. For each parameter, the remaining model parameters were kept at their baseline values.
Table 8.
Summary of the one-factor-at-a-time sensitivity analysis.
Among the investigated parameters and within the considered variation ranges, the auger inertia produces the largest relative variation in rotational irregularity, approximately 2.46%. This stronger local influence arises because the auger is the output member whose rotational irregularity is evaluated. Its inertia therefore acts directly in the auger dynamic equation and determines the amount of oscillatory kinetic energy stored at the output. In contrast, the influence of the perforated-tube inertia is transmitted through the planetary transmission and is partly attenuated by the compliance and damping of the drive system. Consequently, within the investigated ranges, changes in have a stronger direct effect on auger speed fluctuations than comparable changes in tube inertia.
5.4. Rational Parameter Adjustment
The calculations indicate that reducing the effective torsional stiffness assigned to the belt-drive coupling from about 17.2 to 10.3 reduces the start-up rotational irregularity of the auger, evaluated over the interval t = 2–4 s, from approximately 0.435 to 0.420. Under the corresponding operating conditions, motor power consumption decreases from about 2.55 to 2.50 kW, while the auger speed remains close to 1075.5 rpm. Based on these results, – can be considered an engineering compromise range for the investigated drive. Values near the lower bound provide greater torsional compliance and vibration attenuation, whereas values near the upper bound provide a larger margin against excessive belt deformation and slip. Therefore, should be regarded as the lower recommended limit within the investigated conditions rather than a universally applicable design value. Further reduction would require verification of belt pretension and traction capacity to ensure slip-free operation, particularly during start-up torque peaks. In practice, the effective torsional stiffness can be adjusted by changing the belt pretension and tensioner position, increasing the effective compliant belt span, or selecting a belt profile or material with lower longitudinal stiffness. The calculated value should therefore be treated as a target equivalent stiffness of the assembled belt-drive coupling rather than as the material stiffness of an individual belt. Its practical realization should be verified experimentally from the torque–angular displacement response of the assembled transmission while maintaining sufficient belt traction to prevent slip.
6. Discussion
6.1. Physical Interpretation of the Integrated Response
The principal advantage of the proposed formulation is that it preserves the causal path from electromagnetic torque generation to the motion of the technological working members. The motor torque peak first excites relative deformation of the belt. The resulting tube acceleration excites the ring–planet mesh, after which the planet–sun mesh transmits the disturbance to the auger. Therefore, the largest transient torque does not occur simultaneously in all components, and a purely kinematic calculation cannot reproduce the phase relationships or decay rates.
The results agree qualitatively with modern studies of integrated motor–gearbox systems [8,9,10], which show that motor dynamics and mechanical compliance must be solved together. They also support the conclusions of belt-drive research [11,12,13,14,15,16,17,18,19,20], where stiffness, pretension, and damping control the magnitude and persistence of transient oscillations. In the planetary stage, the present reduced model does not describe local mesh-force distribution with the detail of flexible multi-mesh models [21,22,23,24,25,26,27,28,29,30,31], but it captures the system-level energy transmission required for machine-unit design.
6.2. Significance of the Parameter Ranking
Within the investigated parameter ranges, the sensitivity ranking identifies two principal engineering targets. The tube resistance is a technological parameter governed by seed density, tube perforation, friction, and seed distribution. Reducing its fluctuations requires process and geometry improvements. The auger inertia is a design parameter governed by shaft dimensions, flight geometry, and attached gear mass. Within the considered range, increasing the auger inertia increases the stored oscillatory energy and can amplify the speed variation after a disturbance. In contrast, moderate changes in planet-gear inertia within the investigated range have comparatively little effect on the overall response because the planet gears are relatively small and the load is divided among several identical members.
The belt coupling is the most readily adjustable parameter during commissioning and retrofit. However, the result does not imply that the minimum possible stiffness is always desirable. Insufficient stiffness can increase static angular lag, belt slip, and heat generation. The rational design task is therefore to select a belt and pretension that provide adequate mean torque transmission while avoiding excessive excitation of the downstream torsional modes.
6.3. Engineering Implications
For practical design, the start-up torque ratio of 2.61 should be used when checking belt traction, shaft torque, key and spline strength, and gear-tooth loading. Calculations based only on the rated motor torque may underestimate the short-duration load by more than a factor of two. The approximately 3.5 s motor transient and 7 s tube transient also indicate that repeated start–stop operation should be limited or controlled by a soft starter or variable-frequency drive when process conditions permit.
In production machines, the effective compliance of the belt transmission can be tuned by adjusting belt pretension and tensioner position, selecting the belt profile and material, changing belt width or the number of parallel belts, and modifying pulley diameter and wrap angle. Lower pretension or a more compliant belt can improve torsional vibration isolation, whereas excessive compliance may increase belt deformation and the risk of slip. Conversely, higher pretension or a stiffer belt profile improves traction but increases the transmission of transient torsional loads. Therefore, belt selection and tensioner adjustment should provide a compromise between torsional compliance, traction capacity, and belt service life.
The model can be used to evaluate alternative pulley diameters, gear ratios, auger geometry, and tube perforation parameters. It is also suitable as a basis for rational parameter selection and engineering design guidance, provided that experimentally measured stiffness, damping, and technological torque histories are supplied.
The integration of such data would enable prediction not only of rotational irregularity but also of fatigue-relevant torque cycles.
6.4. Limitations
The present formulation is a reduced torsional model intended primarily for predicting the low-frequency torsional response of the coupled drive, including start-up transients, rotational irregularity, and the overall speed and torque response of the working members. It neglects lateral and axial vibration, bearing and housing flexibility, belt transverse modes, gear backlash, time-varying mesh stiffness, manufacturing errors, and unequal load sharing among the planet gears. In particular, the assumption of constant gear-mesh stiffness suppresses the periodic stiffness modulation associated with tooth engagement and therefore does not reproduce the spectral components at the gear-mesh frequency and its sidebands with sufficient fidelity. Neglecting backlash also excludes intermittent tooth contact, impact excitation, and additional high-frequency torsional components that may occur during torque reversals or transient operation. Consequently, the present model should not be used for direct prediction of high-frequency vibration amplitudes or detailed vibration spectra near the gear-mesh frequency. Such analysis would require a higher-fidelity gear-dynamic model incorporating time-varying mesh stiffness, backlash, tooth-contact excitation, and the relevant structural degrees of freedom.
A limitation of the OFAT approach is that it does not quantify interaction effects between simultaneously varying stiffness, damping, inertia, and technological-load parameters; therefore, the reported sensitivity ranking should be interpreted as a local single-parameter assessment.
6.5. Experimental Validation of the Predicted Operating Parameters
To provide direct experimental validation of the predicted steady-state operating parameters, measurements were performed at eight motor-speed levels ranging from 0 to 735 rpm, including the zero-speed condition. The rotational speed of the induction motor was varied using a variable-frequency drive. At each operating point, after the rotational speeds had stabilized, the motor speed (), rotational speed of the seed-removing tube (), and rotational speed of the auger () were measured using a tachometer with a specified measurement accuracy of . Simultaneously, the motor supply voltage and current were recorded to determine the electrical power consumption P. Each steady-state operating condition was measured once; therefore, standard deviations based on repeated measurements were not determined. The experimental speed values reported in Table 9 should therefore be interpreted considering the instrumental measurement accuracy of .
Table 9.
Comparison of experimental and numerically predicted operating parameters for model validation.
The relative error between the calculated and experimental values was determined as
where X denotes the tube speed , auger speed , or motor power P. For the zero-speed condition, the relative error is not defined and is therefore indicated by “–” in Table 9.
The experimental and numerical results show good agreement over the investigated operating range. For the seed-removing tube speed, the relative error ranges from 0.95% to 3.16%, with a maximum value of 3.16%. For the auger speed, the relative error ranges from 1.32% to 4.10%, with a maximum value of 4.10%. The relative error in motor power ranges from 3.07% to 5.02%, with a maximum value of 5.02%. At the nominal motor speed of 735 rpm, the experimental and calculated tube speeds were 367.5 and 363.1 rpm, respectively, corresponding to a relative error of 1.20%. The corresponding experimental and calculated auger speeds were 1102.5 and 1075.5 rpm, with a relative error of 2.45%, while the experimental and calculated motor powers were 2.602 and 2.699 kW, respectively, corresponding to a relative error of 3.72%. Thus, over the investigated non-zero operating points, the maximum deviations did not exceed 3.16% for the tube speed, 4.10% for the auger speed, and 5.02% for motor power. These results provide quantitative experimental support for the ability of the model to reproduce the principal steady-state operating characteristics of the coupled drive.
6.6. Directions for Further Work
Further research aimed at extending the model toward high-frequency vibration prediction should incorporate time-varying gear-mesh stiffness, backlash, tooth-contact excitation, bearing and housing flexibility, and distributed belt dynamics. A multi-objective optimization framework could then be applied to minimize motor power, peak torque, and rotational irregularity while satisfying productivity constraints. Experimental work should quantify the technological torque as a function of seed density and throughput and should identify equivalent belt and mesh damping from measured free-decay or operational-response data.
7. Conclusions
1. A unified reduced-order electromechanical model was developed for the planetary-driven seed-removing machine unit by coupling the induction motor, compliant belt transmission, planetary gear, seed-removing tube, auger, and technological resistance within a single dynamic formulation. The principal contribution is the system-level representation of the interactions between the electrical drive, transmission, and process-loaded working members, rather than the isolated modelling of individual drivetrain components.
2. The analysis demonstrated that the dynamic electromagnetic characteristic of the induction motor must be included when modelling start-up. Its interaction with the compliant belt and planetary transmission governs the propagation of transient torque and speed disturbances through the machine unit and explains the different transient responses of the motor, tube, and auger.
3. Within the investigated parameter ranges, the OFAT sensitivity analysis identified the technological resistance of the seed-removing tube and the inertia of the auger as having the greatest influence on rotational irregularity. In contrast, the inertia and resistance of the planet gears showed a comparatively small system-level influence within the considered ranges. These results provide a physically based local ranking of the investigated parameters for rational parameter selection and engineering design guidance.
4. The study showed that effective belt compliance is an important design parameter linking energy consumption and rotational stability. Appropriate adjustment of belt stiffness and damping can attenuate torsional disturbances and reduce rotational irregularity, although excessive compliance must be avoided because of the associated risk of belt slip and loss of transmission stability.
5. Experimental determination of the rotating-component inertias reduced uncertainty in the model inputs, while measurements of the tube and auger rotational speeds and motor power provided quantitative validation of the predicted steady-state operating characteristics. Over the investigated non-zero operating points, the maximum relative deviations between the numerical predictions and experimental measurements were 3.16% for the tube speed, 4.10% for the auger speed, and 5.02% for motor power. This agreement supports the capability of the model to reproduce the principal steady-state response of the coupled drive within the investigated operating range.
6. The proposed model provides a physically based framework for evaluating transient loads, rotational irregularity, power demand, and parameter sensitivity in planetary-driven cotton-processing machinery. Its predictive scope can be further extended through synchronized transient measurements of torque, speed, current, and vibration and by incorporating time-varying gear-mesh stiffness, backlash, belt transverse dynamics, and support flexibility.
Author Contributions
Conceptualization, D.M. and K.A.; methodology, F.I. and O.A.; software, D.M.; validation, L.Z., B.P. and I.E.; formal analysis, K.A.; investigation, O.M.; resources, I.E. and O.M. All authors have read and agreed to the published version of the manuscript.
Funding
This research was supported by institutional budget funding from the Institute of Mechanics and Seismic Stability of Structures named after M.T. Urazbaev, Uzbekistan Academy of Sciences. No specific grant number was assigned.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Acknowledgments
During the preparation of this manuscript, the authors used ChatGPT (GPT-5.6 Sol, OpenAI, San Francisco, CA, USA, accessed August 2026) for the purposes of English-language editing, improving academic style and clarity, and refining the presentation of the manuscript. The authors reviewed and edited all AI-assisted output and take full responsibility for the content of this publication.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Li, Z.; Zhu, C.; Liu, H.; Gu, Z. Mesh stiffness and nonlinear dynamic response of a spur gear pair considering tribo-dynamic effect. Mech. Mach. Theory 2020, 153, 103989. [Google Scholar] [CrossRef] [Scilit]
- Hu, Z.; Tang, J.; Wang, Q.; Chen, S.; Qian, L. Investigation of nonlinear dynamics and load sharing characteristics of a two-path split torque transmission system. Mech. Mach. Theory 2020, 152, 103955. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Wu, J.; Zhang, N.; Mo, W. Dynamics modeling and shift control of a novel spring-based synchronizer for electric vehicles. Mech. Mach. Theory 2022, 168, 104586. [Google Scholar] [CrossRef] [Scilit]
- Mo, W.; Walker, P.D.; Tian, Y.; Zhang, N. Dynamic analysis of unilateral harpoon-shift synchronizer for electric vehicles. Mech. Mach. Theory 2021, 157, 104173. [Google Scholar] [CrossRef] [Scilit]
- Tian, Y.; Zhang, N.; Zhou, S.; Walker, P.D. Model and gear shifting control of a novel two-speed transmission for battery electric vehicles. Mech. Mach. Theory 2020, 152, 103902. [Google Scholar] [CrossRef] [Scilit]
- Lin, C.; Hu, Y.; Wei, Y.; Cai, Z. Characteristics analysis of supporting and locking mechanism based on the non-circular gear compound transmission. J. Mech. Sci. Technol. 2020, 34, 2561–2571. [Google Scholar] [CrossRef] [Scilit]
- Veciana, J.M.; Nebot, L.J.; Garcia, E.L. Residual vibration reduction in back-and-forth moving systems driven by slider-crank mechanisms working through a dead point configuration. Mech. Mach. Theory 2021, 158, 104239. [Google Scholar] [CrossRef] [Scilit]
- Cerrada, M.; Jiménez-Santín, D.; Ortega, R.; Aller, J.M.; Cabrera, D.; Sánchez, R. A simple yet realistic integrated dynamical modeling of an induction motor and one-stage spur gearbox system with broken tooth. Mech. Mach. Theory 2024, 200, 105694. [Google Scholar] [CrossRef] [Scilit]
- Yousfi, B.E.; Soualhi, A.; Medjaher, K.; Guillet, F. Electromechanical modeling of a motor–gearbox system for local gear tooth faults detection. Mech. Syst. Signal Process. 2022, 166, 108435. [Google Scholar] [CrossRef] [Scilit]
- Szolc, T.; Konowrocki, R.; Michajłow, M.; Pręgowska, A. An investigation of the dynamic electromechanical coupling effects in machine drive systems driven by asynchronous motors. Mech. Syst. Signal Process. 2014, 49, 118–134. [Google Scholar] [CrossRef] [Scilit]
- Zhu, H.; Zhu, W.D.; Fan, W. Dynamic modeling, simulation and experiment of power transmission belt drives: A systematic review. J. Sound Vib. 2021, 491, 115759. [Google Scholar] [CrossRef] [Scilit]
- Yu, Z.; Cui, Y.; Zhang, Q.; Liu, J.; Qin, Y. Thermo-mechanical coupled analysis of V-belt drive system via absolute nodal coordinate formulation. Mech. Mach. Theory 2022, 174, 104906. [Google Scholar] [CrossRef] [Scilit]
- Sun, Y.; Shangguan, W.; Jiang, J.; Rakheja, S. Modeling of serpentine belt accessory drive system coupled vibrations and utilizing nonlinear tensioner to enhance performances. Mech. Syst. Signal Process. 2022, 178, 109308. [Google Scholar] [CrossRef] [Scilit]
- Xu, M.; Zhang, H.; Miao, H.; Hao, J.; Li, C.; Song, W.; Yao, G.; Zhang, Y. Model-based vibration response analysis and experimental verification of lathe spindle-housing-belt system with rubbing. Mech. Syst. Signal Process. 2023, 186, 109841. [Google Scholar] [CrossRef] [Scilit]
- Bortnowski, P.; Kawalec, W.; Król, R.; Ozdoba, M. Identification of conveyor belt tension with the use of its transverse vibration frequencies. Measurement 2022, 190, 110706. [Google Scholar] [CrossRef] [Scilit]
- Khalifa, R.M.; Yacout, S.; Bassetto, S.; Shaban, Y. Experimental vibration data collected for a belt drive system under different operating conditions. Data Brief 2023, 48, 109175. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Khalifa, R.M.; Yacout, S.; Bassetto, S.; Shaban, Y. Condition monitoring and warning of a belt drive system based on a logical analysis of data regression-based residual control chart. Struct. Health Monit. 2025, 24, 1657–1673. [Google Scholar] [CrossRef] [Scilit]
- Wenting, N.; Dayu, Z. An approach of FEM analysis of the influence of pretension on the transverse vibration of belt drive. J. Phys. Conf. Ser. 2019, 1345, 032032. [Google Scholar] [CrossRef] [Scilit]
- Long, S.; Yin, Z.; Zhao, X.; Shangguan, W. Methods for estimating hysteretic behavior and vibration responses of a timing belt tensioner. Adv. Mech. Eng. 2019, 11, 1–19. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Ding, J.; Ding, H.; Chen, L. Nonlinear parametric vibration and stability analysis of axially moving belt with non-homogeneous boundaries. Eur. J. Mech.-A/Solids 2026, 115, 105837. [Google Scholar] [CrossRef] [Scilit]
- Sanchez-Espiga, J.; Fernandez-del-Rincon, A.; Iglesias, M.; Viadero, F. Influence of errors in planetary transmissions load sharing under different mesh phasing. Mech. Mach. Theory 2020, 153, 104012. [Google Scholar] [CrossRef] [Scilit]
- Sanchez-Espiga, J.; Fernandez-del-Rincon, A.; Iglesias, M.; Viadero, F. Planetary gear transmissions load sharing measurement from tooth root strains: Numerical evaluation of mesh phasing influence. Mech. Mach. Theory 2021, 163, 104370. [Google Scholar] [CrossRef] [Scilit]
- Sanchez-Espiga, J.; Fernandez-del-Rincon, A.; Iglesias, M.; Viadero, F. Numerical evaluation of the accuracy in the load sharing calculation using strain gauges: Sun and ring gear tooth root. Mech. Mach. Theory 2022, 175, 104923. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Wei, J.; Wang, F.; Hou, S.; Zhang, A.; Lim, T.C. Dynamic model and load sharing performance of planetary gear system with journal bearing. Mech. Mach. Theory 2020, 151, 103898. [Google Scholar] [CrossRef] [Scilit]
- Ryali, L.; Talbot, D.; Kahraman, A. A dynamic load distribution model of planetary gear sets. Mech. Mach. Theory 2021, 158, 104229. [Google Scholar] [CrossRef] [Scilit]
- Ryali, L.; Talbot, D. A dynamic gear load distribution model for epicyclic gear sets with a structurally compliant planet carrier. Mech. Mach. Theory 2023, 181, 105225. [Google Scholar] [CrossRef] [Scilit]
- Dai, H.; Chen, F.; Xun, C.; Long, X. Numerical calculation and experimental measurement for gear mesh force of planetary gear transmissions. Mech. Syst. Signal Process. 2022, 162, 108085. [Google Scholar] [CrossRef] [Scilit]
- Jianjun, T.; Hao, L.; Hao, T.; Caichao, Z.; Chaosheng, S.; Yehong, D.; Zhangdong, S. Dynamic modeling and analysis of planetary gear train system considering structural flexibility and dynamic multi-teeth mesh process. Mech. Mach. Theory 2023, 186, 105348. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Hu, N.; Li, Y.; Cheng, Z.; Shen, G. Dynamic modeling and analysis of planetary gear system for tooth fault diagnosis. Mech. Syst. Signal Process. 2024, 207, 110946. [Google Scholar] [CrossRef] [Scilit]
- Wang, C.; Yu, L.; Wang, H.; Zhang, B.; Luo, H. Fault modulation mechanism and kinematic modeling of planetary gear with local fault. J. Sound Vib. 2024, 590, 118572. [Google Scholar] [CrossRef] [Scilit]
- Molaie, M.; Deylaghian, S.; Iarriccio, G.; Samani, F.S.; Zippo, A.; Pellicano, F. Planet Load-Sharing and Phasing. Machines 2022, 10, 634. [Google Scholar] [CrossRef] [Scilit]
- Guida, R.; Bertolino, A.C.; Martin, A.D.; Sorli, M. A new computationally efficient model of the non-linear dynamics in harmonic drive reducers. Mech. Mach. Theory 2025, 209, 105992. [Google Scholar] [CrossRef] [Scilit]
- Ayankoso, S.; Dutta, A.; He, Y.; Gu, F.; Ball, A.; Pal, S.K. Performance of vibration and current signals in the fault diagnosis of induction motors using deep learning and machine learning techniques. Struct. Health Monit. 2026, 25, 196–212. [Google Scholar] [CrossRef] [Scilit]
- Ermolaev, A.; Erofeev, V.; Plekhov, A.; Titov, D. Magnetic vibration in induction motor caused by supply voltage distortion. Energies 2022, 15, 9600. [Google Scholar] [CrossRef] [Scilit]
- Kharchenko, Y.; Tchaban, V.; Butrynskyi, D.; Bilovus, A.; Okhrymovych, A. Modeling of asynchronous motor vibrations. Vibroeng. Procedia 2025, 59, 230–236. [Google Scholar] [CrossRef] [Scilit]
- Bruinsma, S.; Geertsma, R.; Loendersloot, R.; Tinga, T. Automated tacholess rotational speed estimation on asynchronous motors for improved vibration analysis. Results Eng. 2025, 27, 106475. [Google Scholar] [CrossRef] [Scilit]
- Gelman, L.; Kerrouche, R. Novel vibration diagnosis technologies for lubrication deficiency in rolling bearings of induction motors. Energies 2026, 19, 1741. [Google Scholar] [CrossRef] [Scilit]
- Chen, X.; Han, S.; Li, J.; Deng, T.; Wei, H. Investigation of electromechanical coupling lateral/torsional vibration in a high-speed rotating continuous flexible shaft of PMSM. Appl. Math. Model. 2020, 77, 506–521. [Google Scholar] [CrossRef] [Scilit]
- Muc, A.; Bielecka, A. Transmission of mechanical vibrations in an electric drive unit with scalar control—Comparative analysis with evaluation based on experimental studies. Energies 2025, 18, 5140. [Google Scholar] [CrossRef] [Scilit]
- Hao, J.; Yao, Z.; Hua, C.; Yu, C.; Li, C. Bending-torsional coupling vibration characteristics of asynchronous motorized spindle considering electromechanical coupling and multi-excitation effect. Mech. Syst. Signal Process. 2024, 208, 111039. [Google Scholar] [CrossRef] [Scilit]
- Laine, S.; Hakonen, U.; Hartikainen, H.; Viitala, R. Frequency domain solution method for electromagnetic influence analysis on torsional vibrations. J. Sound Vib. 2025, 596, 118780. [Google Scholar] [CrossRef] [Scilit]
- Peng, T.; Yan, Q. Torsional vibration analysis of shaft with multi inertias. Sci. Rep. 2022, 12, 7333. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Chen, C.; Li, Q.; Wang, W. Torsional vibration feature extraction method from lateral vibrations based on decomposed forward and backward whirl motions. J. Sound Vib. 2023, 547, 117491. [Google Scholar] [CrossRef] [Scilit]
- Al-Hababi, T.; Cao, M.; Saleh, B.; Alkayem, N.F.; Xu, H. A critical review of nonlinear damping identification in structural dynamics: Methods, applications, and challenges. Sensors 2020, 20, 7303. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Biswas, S.; Banerjee, A.; Bera, K.K. An analytical and experimental investigation into overall dissipation of flexural mode in a periodically damped beam. Mech. Mater. 2024, 198, 105113. [Google Scholar] [CrossRef] [Scilit]
- Chen, L.; Wu, Q. Numerical and experimental investigation of vibration and damping performance of additively manufactured mechanical metamaterials. Results Eng. 2025, 28, 108258. [Google Scholar] [CrossRef] [Scilit]
- Gavula, A.; Hubinský, P.; Babinec, A. Damping of oscillations of a rotary pendulum system. Appl. Sci. 2023, 13, 11946. [Google Scholar] [CrossRef] [Scilit]
- Mukhammadiev, D.M.; Ibragimov, F.K.; Mukhammadiev, T.D. Modeling the motion of a saw ginning machine. J. Mach. Manuf. Reliab. 2020, 49, 256–262. [Google Scholar] [CrossRef] [Scilit]
- Mukhammadiev, D.M.; Ergashev, I.O. Investigation of seeds mechanical extraction through the seed-removing device from saw gin. E3S Web Conf. 2023, 390, 06011. [Google Scholar] [CrossRef] [Scilit]
- Abdugaffarov, K.J.; Zhamolova, L.Y. Dynamic investigations of cotton-processing machine components. AIP Conf. Proc. 2023, 2789, 040139. [Google Scholar] [CrossRef] [Scilit]
- Hoshimov, A. Condition monitoring and fault diagnosis of saw of gin machine using vibration analysis. Web Technol. Multidimens. Res. J. 2025, 3, 52–66. Available online: https://webofjournals.com/index.php/4/article/view/5296 (accessed on 20 August 2026).
- Imomqulov, S.; Rustamov, R. The effect of vibrations in the cylinder of the gin machine saw on power consumption and optimization pathways. Am. J. Technol. Adv. 2025, 2, 86–92. Available online: https://semantjournals.org/index.php/AJTA/article/view/2380/1868 (accessed on 20 August 2026).
- Pelletier, M.G.; Holt, G.A.; Wanjura, J.D. Cotton gin stand machine-vision inspection and removal of plastic contamination: Software Design. AgriEngineering 2021, 3, 494–518. [Google Scholar] [CrossRef] [Scilit]
- Donohoe, S.P.; Alege, F.P.; Thomas, J.W. A Tool for Semi-Automated Extraction of Cotton Gin Energy Consumption from Power Data. AgriEngineering 2023, 5, 1498–1529. [Google Scholar] [CrossRef] [Scilit]
- Abdisalomov, M.S. Justification of Perforation and Drive Parameters of the Seed-Removing Tube. Ph.D. Thesis, Scientific Research Institute of Fibrous Crops, Tashkent, Uzbekistan, 2025. (In Russian) [Google Scholar]
- Miroshnichenko, G.I. Fundamentals of Design of Cotton Primary-Processing Machines; Mashinostroenie: Moscow, Russia, 1972. (In Russian) [Google Scholar]
- Tursunov, H.K. Mechanics of Working Members of Fiber-Cleaning Machines; Fan: Tashkent, Uzbekistan, 1997. (In Russian) [Google Scholar]
- Ben Hazem, Z.; Fotuhi, M.J.; Bingül, Z. A comparative study of the joint neuro-fuzzy friction models for a triple link rotary inverted pendulum. IEEE Access 2020, 8, 49066–49078. [Google Scholar] [CrossRef] [Scilit]
- Levin, A.E. Mathematical Modeling of Machine-Tool Drives. Theory of Mechanisms and Machines; Nauka: Alma-Ata, Russia, 1977; pp. 259–260. (In Russian) [Google Scholar]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.