


Abstract
This paper investigates the synchronization problem of fractional-order coupled neural networks (FOCNNs) featuring higher-order interactions and mixed delays under an event-dependent intermittent control framework. The proposed model incorporates higher-order interactions to more accurately capture the complex cooperative behaviors observed in real neural systems. To facilitate analysis, several novel theoretical tools are developed, which extend the existing framework of fractional-order control and provide upper bounds for the solutions of delayed fractional-order systems. Furthermore, a new event-dependent intermittent controller is designed, and sufficient synchronization criteria are rigorously derived. Finally, numerical simulations are presented to verify the effectiveness and robustness of the proposed control strategy.
1. Introduction
Coupled neural networks (CNNs), as a representative class of complex dynamical networks, have attracted considerable research attention over the past few decades. A CNN consists of numerous interconnected nodes, each describing an individual dynamic neural subsystem. Unlike conventional neural networks, CNNs not only exhibit the intrinsic dynamic properties of neural systems but also demonstrate richer and more complex behaviors arising from their topological structures and inter-node interactions. Owing to these characteristics, CNNs have been extensively applied in diverse fields such as signal processing, pattern recognition, and speech analysis [1,2,3]. Among the various dynamic behaviors of CNNs, synchronization stands out as a fundamental cooperative phenomenon in both natural and artificial systems, with significant practical implications for areas including power transmission, robotic coordination, and multi-agent collaboration [4,5,6].
Recent advances in the study of CNNs have motivated researchers to employ fractional calculus as a powerful mathematical tool for modeling their complex dynamical behavior [7,8,9]. Compared with traditional integer-order calculus, fractional calculus provides a more effective framework for characterizing the intricate features of complex systems, particularly those exhibiting memory effects and multi-time-scale dynamics [10,11,12]. Consequently, increasing attention has been devoted to the study of fractional-order coupled neural networks (FOCNNs). By introducing fractional-order operators into conventional CNNs, these networks inherit the memory-dependent properties of fractional calculus and exhibit a wider range of dynamic behaviors, such as bifurcation, chaos, and multistability [13,14]. Therefore, this work focuses on the synchronization analysis of fractional-order coupled neural networks.
In neuroscience, increasing evidence indicates that interactions among brain regions often arise from collective activity involving multiple nodes rather than simple pairwise connections. This motivates the study of higher-order interaction networks [15,16]. To capture such complex cooperative behaviors, researchers have developed models based on hypergraphs and simplicial complexes, which describe group-wise interactions and offer a richer representation of structural and functional relationships in neural systems [17,18]. Recent studies have further illustrated their significance: for instance, Mehrabbeik et al. [19] analyzed how higher-order coupling parameters affect the dynamics of memristive Rulkov neurons, while Farrera-Megchun et al. [20] investigated the impact of higher-order interactions in networks of Huber–Braun neurons. These advances show that higher-order interaction networks provide powerful tools for understanding complex neural dynamics, underscoring their theoretical and practical importance.
With the increasing demand for stability, efficiency, and energy optimization in modern engineering systems, intermittent control has attracted considerable attention as an effective control strategy [21,22,23]. By activating control inputs only during selected time intervals, intermittent control avoids continuous actuation, alleviates abrupt state variations, and significantly reduces energy consumption and operational costs. Over the past decade, its effectiveness has been widely demonstrated in various control systems. For instance, Sang [24] proposed an intermittent control scheme for the exponential synchronization of chaotic neural networks with actuator saturation, while Ding et al. [25] developed an event-dependent intermittent strategy for delayed discrete-time neural networks, with stability conditions derived via linear matrix inequalities.
Event-triggered or event-dependent control has become a major research trend in fractional-order systems. Xue et al. [26] proposed intermittent event-triggered control for complex networks and established new stability criteria. Hu et al. [27] further developed a fixed time event-dependent intermittent strategy for reaction-diffusion systems. More recently, event-dependent intermittent control has been extensively studied for large-scale networked systems due to its ability to further reduce communication burden and computational overhead [28,29]. unlike standard event-triggered methods, the proposed event-dependent intermittent control mechanism integrates event-triggering with intermittent actuation, ensuring that control updates occur only when necessary within active intervals. However, the presence of time delays, which are inevitable in neural signal transmission, may induce oscillations or even instability [30,31]. Compared with integer-order systems, fractional-order systems exhibit inherent memory effects, making delay-dependent control more challenging. To date, intermittent control for fractional-order systems with mixed delays remains insufficiently explored, which motivates the present study.
Existing synchronization studies on fractional-order neural networks have mainly focused on pairwise interactions or single-delay structures, leaving the combined effects of higher-order interactions and mixed delays largely unexplored. Moreover, most intermittent control strategies rely on pre-designed periodic schemes, which may lead to unnecessary control updates. To address these gaps, this work develops an event-dependent intermittent framework tailored to fractional-order systems with complex coupling structures.
- 1.
- Higher-order interactions are incorporated into the FOCNN model, allowing a more accurate description of multi-neuronal coordination and overcoming the limitations of traditional pairwise interaction frameworks [24,25].
- 2.
- A fractional Halanay inequality with an explicit solution upper bound is established, which extends existing results for single-delay systems and provides an effective tool for stability analysis of delayed fractional-order networks [30,32].
- 3.
- An event-dependent intermittent control strategy is adopted, which relaxes the strict time constraints on control action and effectively handles the memory effect and mixed delays in fractional-order systems. Based on this scheme, synchronization criteria for FOCNNs are further derived [25,30,33].
Structure: The essential preliminaries and model descriptions are presented in Section 2. The synchronization criteria for FOCNNs are derived in Section 3. Two numerical simulations are conducted in Section 4 to validate the theoretical results. Finally, conclusions are summarized in Section 5.
Notations: The notations used in this paper are described as follows. denotes the set of natural numbers; represents the set of real numbers; stands for the set of positive real numbers; denotes the -dimensional real space; is the N-dimensional identity matrix; represents a diagonal matrix; denotes the Laplace transform of ; indicates the maximum eigenvalue of matrix A; denotes the set of continuously differentiable functions defined on ; The symbol ⊗ denotes the Kronecker product.
2. Preliminaries and Model Description
2.1. Preliminaries
Definition 1
([34]). For a continuously differentiable function , the Caputo fractional derivative of order is defined as
where denotes the initial time, represents the time derivative of , denotes the Gamma function.
Definition 2
([34]). With two parameters , , the Mittag-Leffler function is defined as
where . Denoting , its one-parameter form is described as
Especially,
Lemma 1
([34]). Consider the fractional-order differential equation
where is continuously differentiable, and . Then we have
Lemma 2
([35]). Let and . If there exists such that and for , then
Lemma 3
([36]). Assume that . If all poles of are in the open left-half complex plane, then
Lemma 4
([37]). Given any real matrices X, Y, positive definite matrix P with appropriate dimensions and a constant , such that
Lemma 5.
For the Mittag-Leffler function with and , then
Proof.
By the integral mean value theorem, for any , there exists such that
Subsequently, we can obtain
By applying the mean value theorem, there exists satisfying
where
According to [34] and Lemma 3
Therefore, for any , there exists such that
for Then, we obtain
which implies
□
Lemma 6.
Assume that , for and
where , , , , , . Then for .
Proof.
We claim that for . If the claim is false, there must exist a time such that for and . It follows from Lemma 2 that . However, from the condition (1), we obtain
which is a contradiction. Therefore, for . □
Lemma 7.
Let be bounded on , and . If such that
where ξ, and are positive constants, then
for , where
and is determined by
Proof.
Define the continuous auxiliary function as
By the monotonicity of the Mittag–Leffler function and Lemma 5, there exist positive constants and such that
and
Consequently, it follows that
Therefore, there exists a constant
such that .
Then, define
for and for . By the properties of the Mittag-Leffler function [34], we have
When , derived from (4) and (6),
where and
For , we obtain the following by combining (4) and (6)
Thus, for , it follows from (2), (7) and (8) that
where and for . By Lemma 6, we have , which implies that for . Consequently, inequation (3) holds. □
Remark 1.
The inequality can be written explicitly as a constraint on the delay: provided that . If , then no admissible delay τ exists. Hence, for fixed ξ, , and , the delay τ is bounded from above; if ξ is a tunable (design) parameter, increasing ξ allows larger admissible delays.
Remark 2.
Traditional fractional Halanay-type inequalities (e.g., [32,38]) usually provide only an asymptotic result such as , which is adequate for studying global synchronization but insufficient for systems whose dynamics evolve in a piecewise manner. In the present work, the event-dependent control induces a sequence of switching intervals, and thus explicit upper bounds of the state norm on each interval are required. When applied to systems with mixed discrete and distributed delays, classical inequalities either fail to capture the interaction of the delay types or lead to overly conservative estimates. Lemma 7 overcomes these limitations by producing interval-wise upper bounds expressed via the Mittag–Leffler function, thereby enabling a refined analysis suited to the mixed-delay, piecewise dynamics considered in this paper.
Lemma 8.
Let be bounded on If
where , and +, then
for and .
Proof.
Let be an auxiliary comparison function defined by
with the initial condition
From Lemma 1 and Equation (10) that
which implies for .
For , we obtain the following by combining (9) and (10)
where , and for .
Then, we claim that for . If the claim is false, there must exist a time such that for and . It follows from Lemma 2 that . From (11), we have and for . Hence, we obtain
which leads to a contradiction. Therefore,
□
Remark 3.
The convergence of the system for is established in Lemma 7, while an explicit upper bound of the solution for is derived in Lemma 8. These two lemmas together provide a complete analytical characterization of the system over the entire parameter range. Moreover, the proposed upper-bound estimation method is computationally feasible and offers a solid theoretical basis for subsequent controller design.
2.2. Model Description
The mathematical model for the controlled FOCNN with n nodes and s-dimensional interactions takes the following form
where , , , , …, denotes the state vector of the node i and , presents the activation function, = diag is the self-regulation matrix, , , are connection weight matrices, , , …, denotes time-varying external input, is control input, represents the time delay with initial condition for , we suppose that and . For , the positive definite matrix denotes the internal coupling matrix. The coupling strengths for are nonlinear coupling functions of rth-dimension, satisfying . If the r-dimensional simplex is connected in the simplicial complex, then holds for any permutation of the indices . Otherwise, . From [39], the r-th coupling function is governed by
The concept of the classical Laplacian matrix is extended in [40]. The Laplacian matrix for r-order interactions can be defined as
where
Therefore, model (13) can be expressed as
The isolated nodes of network (13) follow
where , and for .
Define synchronization error as the . Then, one yields
Assumption 1.
There exists constant such that
for .
3. Main Result
The control objective is to ensure that all trajectories of system (13) asymptotically synchronize with the target dynamics (15), such that the system error satisfy . To reduce energy consumption, we propose an energy-efficient intermittent control framework with the following
where is control gain. if the control input is active and affects the system dynamics for , and if there is no control input for . To establish the triggering sequence , we define a decaying threshold function with the asymptotic property . The event times are then determined iteratively by
Remark 4.
Event-dependent intermittent control regulates the controller’s active and rest states through dynamic triggering mechanisms (e.g., state thresholds). In contrast to traditional periodic intermittent controllers [21,33], our proposed control scheme (17) incorporates an event-triggered mechanism that flexibly adjusts the controller’s working and resting states based on actual demands. This approach enables the control strategy to better align with the system’s real-time operational requirements, significantly enhancing control adaptability and precision.
Theorem 1.
Under Assumption 1, the system (13) can achieve synchronization under the controller (17) if
where , and
Proof.
Construct the Lyapunov function candidate Further, it can be computed that
where . By Lemma 4 and Assumption 1, the following inequalities hold:
It can be deduced that
where , , …, . Hence, we can derive
where . Next, the system behavior is analyzed under varying threshold function configurations.
If for , from (18), we have
where . Applying the fractional-order Halanay-type inequality given in Lemma 7, we derive that
where .
If for . From (18) we can obtain and
Further, by Lemma 8 and Equation (20), one can get
where , . Note that we require , as control is unnecessary for systems with naturally asymptotic decay.
Hence, combining (19) and (21) we can conclude that
for .
For any , we have
where . Hence,
For any , we get
where . Therefore
where .
For any , we get
Further,
Thus, one concludes that, for any and , there exists
and from (22) and (23), we get
Note that , for any , there must exist a such that
Hence, we have
for , which implies , . □
Remark 5.
Theorem 1 first presents a criterion for achieving synchronization in fractional-order systems with complex delays using intermittent control. In previous studies [41,42], it has been challenging to obtain upper bounds for the states of fractional-order delay systems. By utilizing Lemmas 7 and 8, we derived the upper bounds for both the controlled and uncontrolled systems. Based on these results, we established a synchronization criterion, providing new insights and approaches for further research on intelligent control of fractional-order delay systems.
Remark 6.
When , controller (17) degenerates into a continuous controller. Remarkably, the synchronization of the system can still be guaranteed under controller (17) with the conditions specified in Theorem 1. This special case not only demonstrates the flexibility of our control strategy but also verifies the generality of the proposed theoretical results.
The switching mechanism , being governed by the threshold function , exhibits degenerate behavior when specific forms of are adopted. In particular, the controller (17) reduces to classical intermittent control for certain selections.
where and for . Combining system (13) and controller (24), the error system can be rewritten as
Theorem 2.
Under Assumption 1, then the network (25) can achieve synchronization under the control protocol (24) if
where , , and is given by
Proof.
Construct the Lyapunov function candidate
From the analytical framework established in Theorem 1, we can derive
Moreover, resulting from Lemma 7 and Theorem 1, we have
Then, for any , we have
For any , one gets
Thus, one concludes that, for any , there exists
For any , there have
Note that . Hence, for any , there must exists a such that
for . Consequently, it is straightforward to derive that . □
Remark 7.
Intermittent controller (24) is the classic form currently used to address fractional-order systems. Due to the special memory properties of fractional-order systems and the lack of relevant tools, there has been no research on intermittent control for delay fractional-order systems in the existing literature. Theorem 2, based on the results obtained in this paper, successfully overcomes the challenges posed by the memory effects of fractional-order systems and the impact of system delays on synchronization.
4. Numerical Examples
Two numerical examples validate the efficacy of our theoretical findings, showcasing network synchronization under the proposed intermittent control scheme.
Example 1.
Consider the following FOCNN with higher-order interactions, in which network is described as
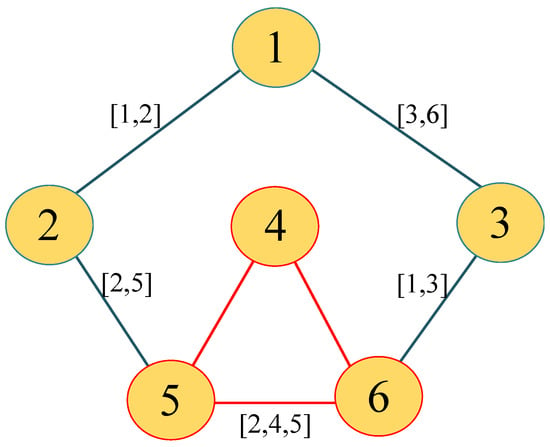
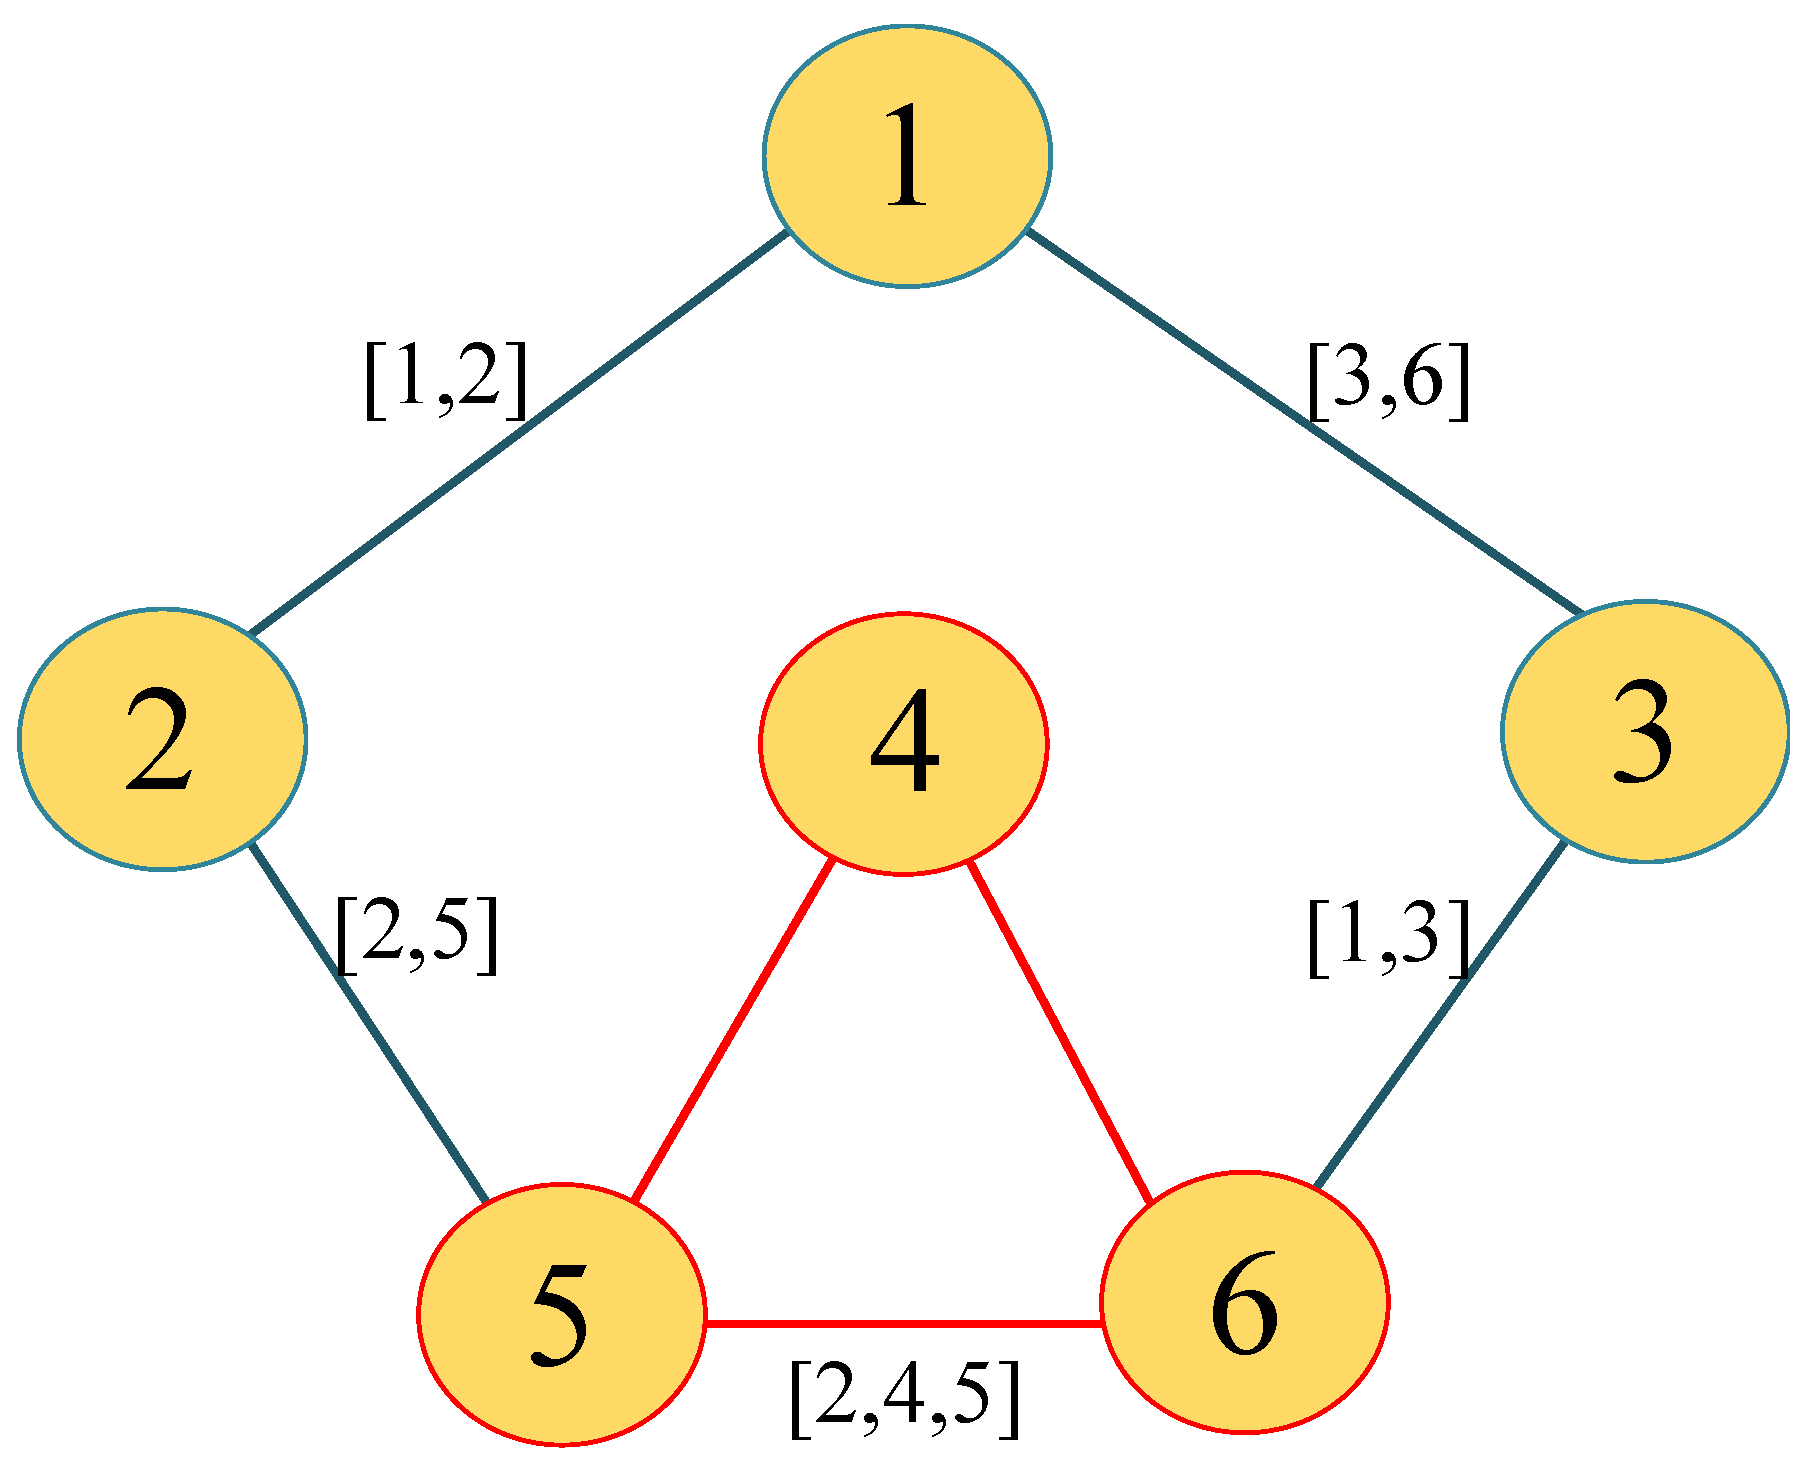
where , , = tanh, = , and , . It is clear that Assumption 1 holds. Assume that , , , , , , . The topology structure of model (27) is shown in Figure 1. Meanwhile, the corresponding Laplacian matrices are
Figure 1.
2-simplicial complex formed by 6 nodes, where , , , represent 1-simplex and denotes 2-simplex.
The initial values of networks (27) are randomly chosen as follows: , , , , , . Let the prescribed threshold function , and the control gain is established by Theorem 1.
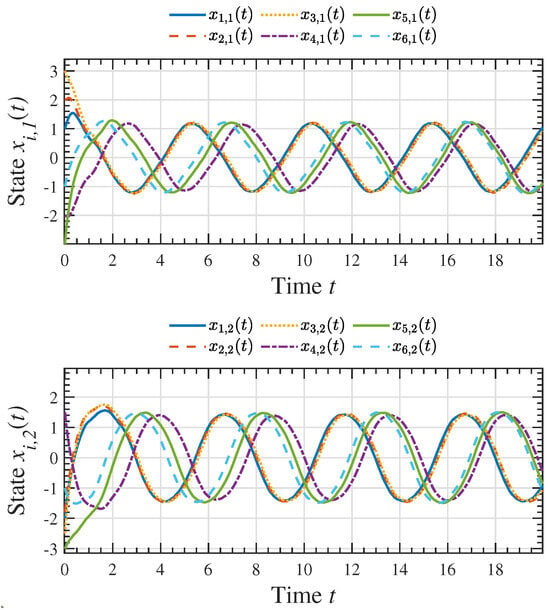
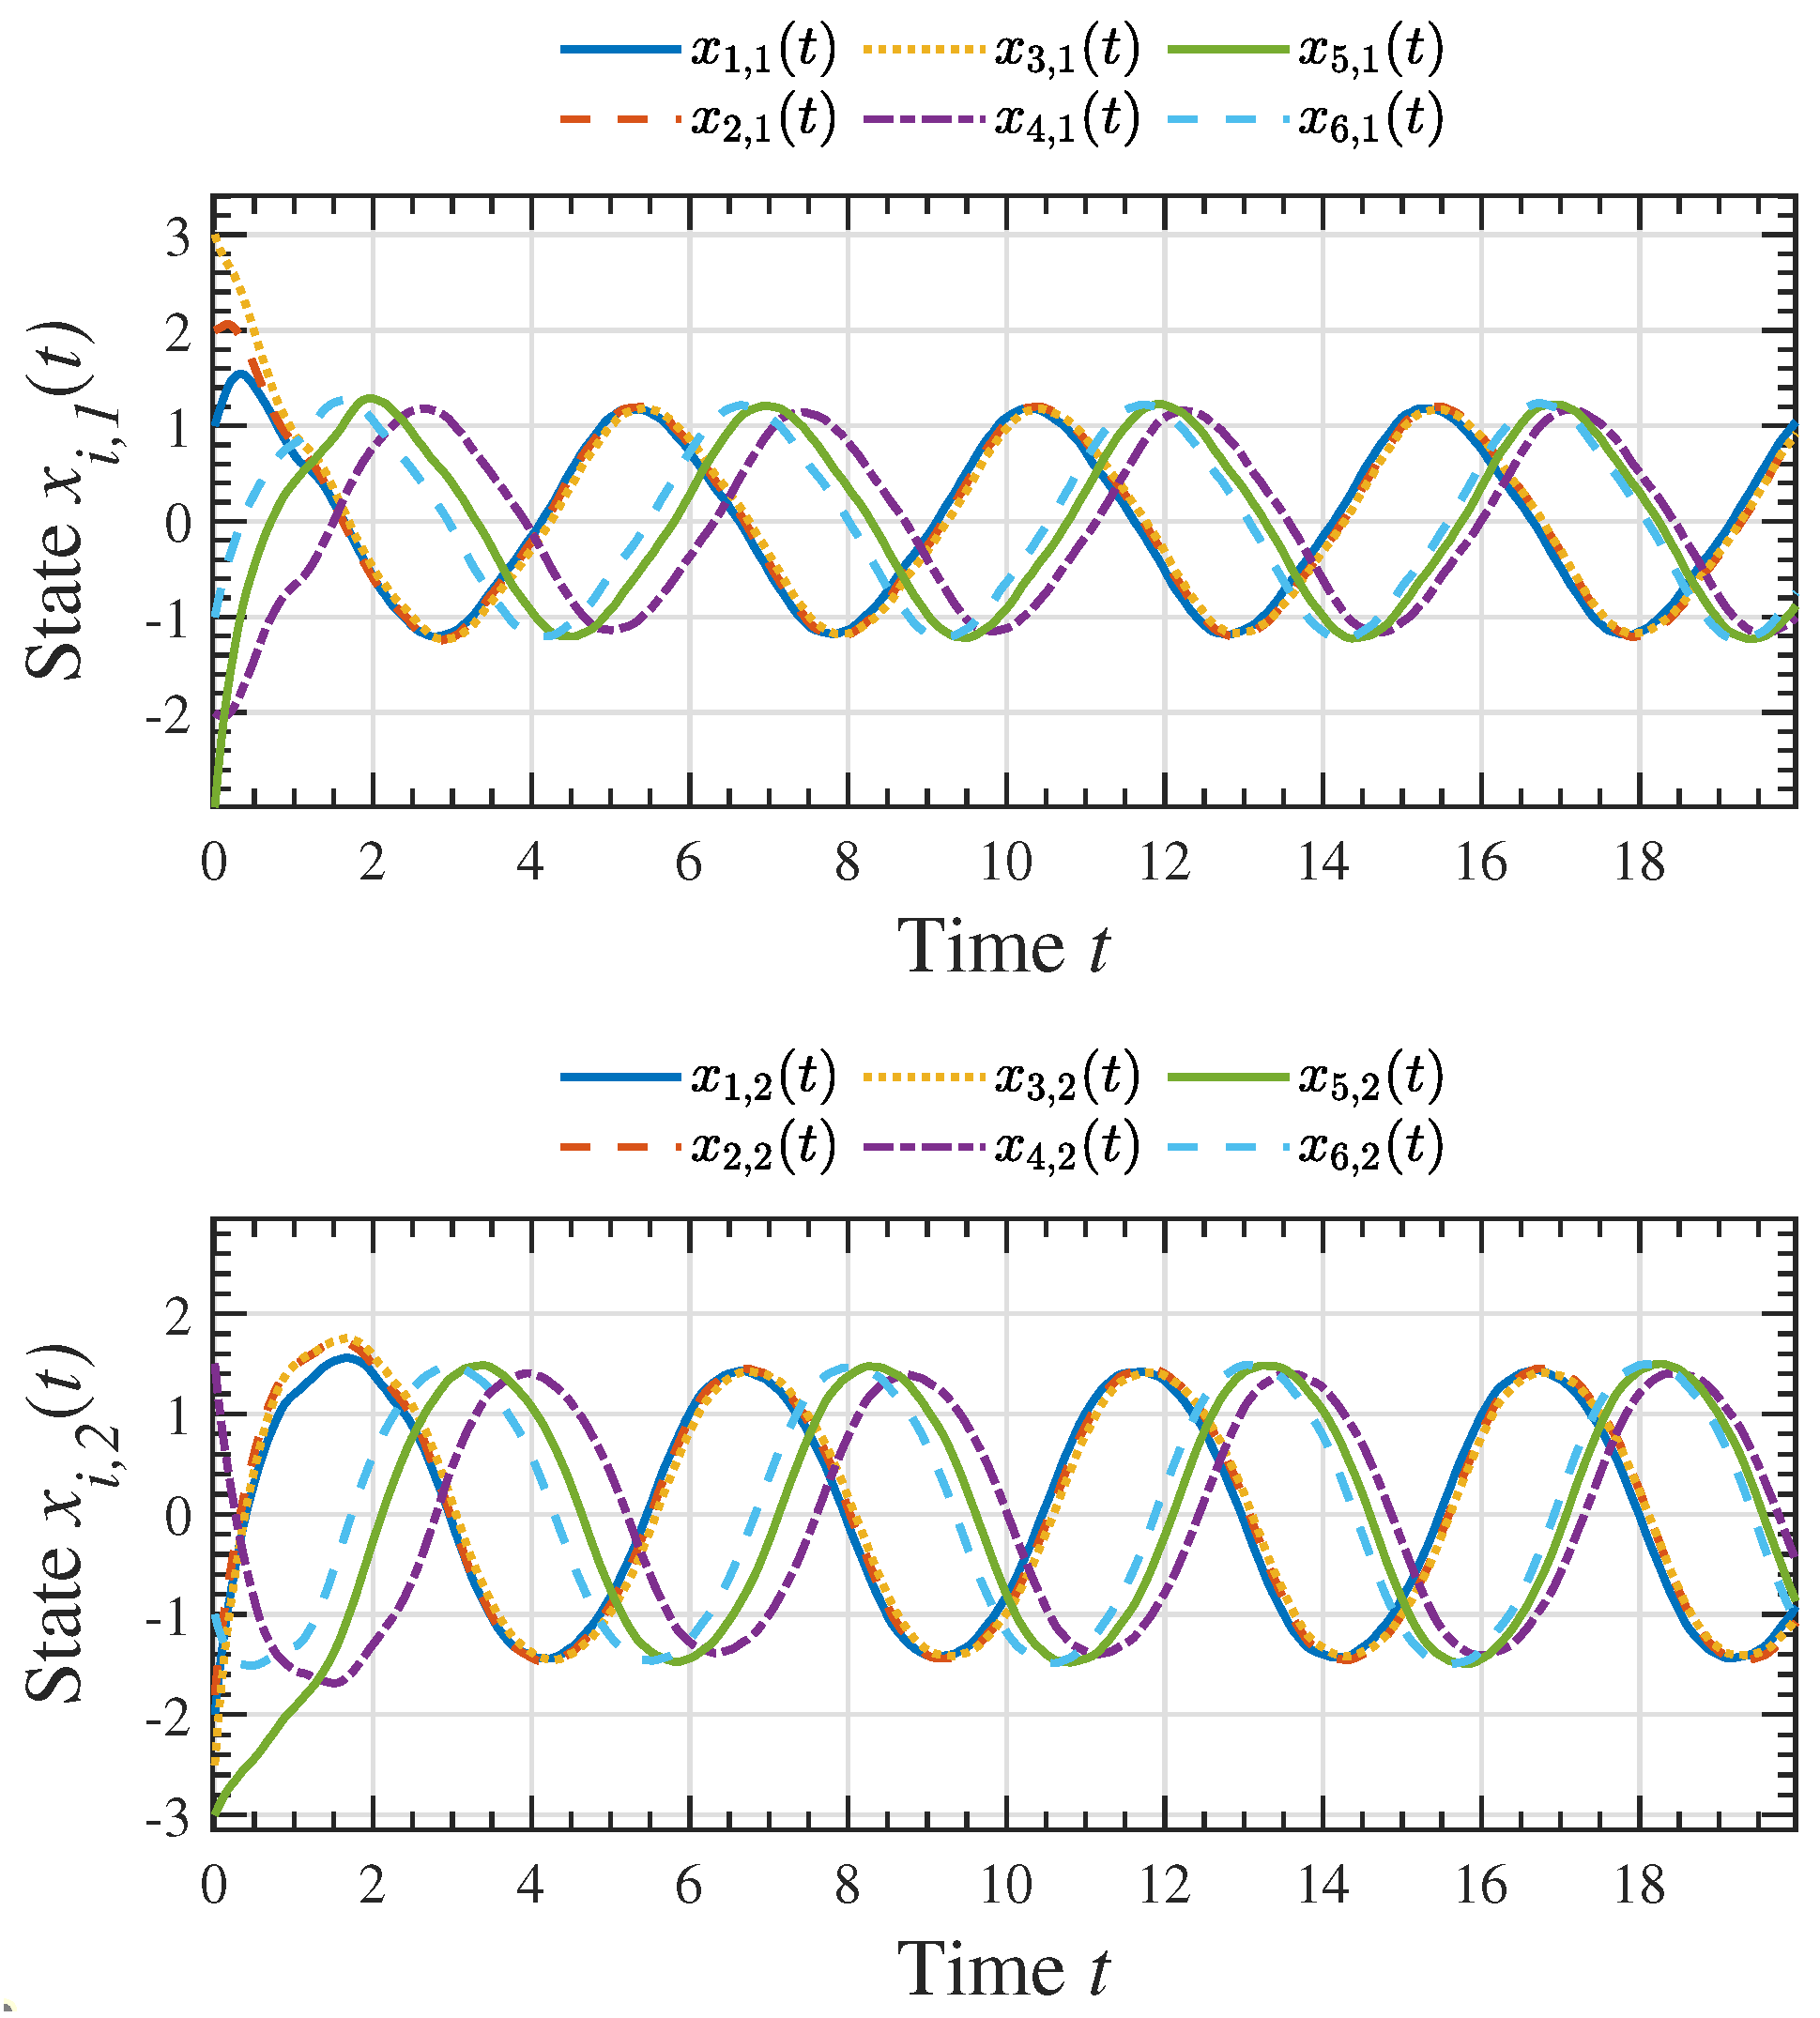
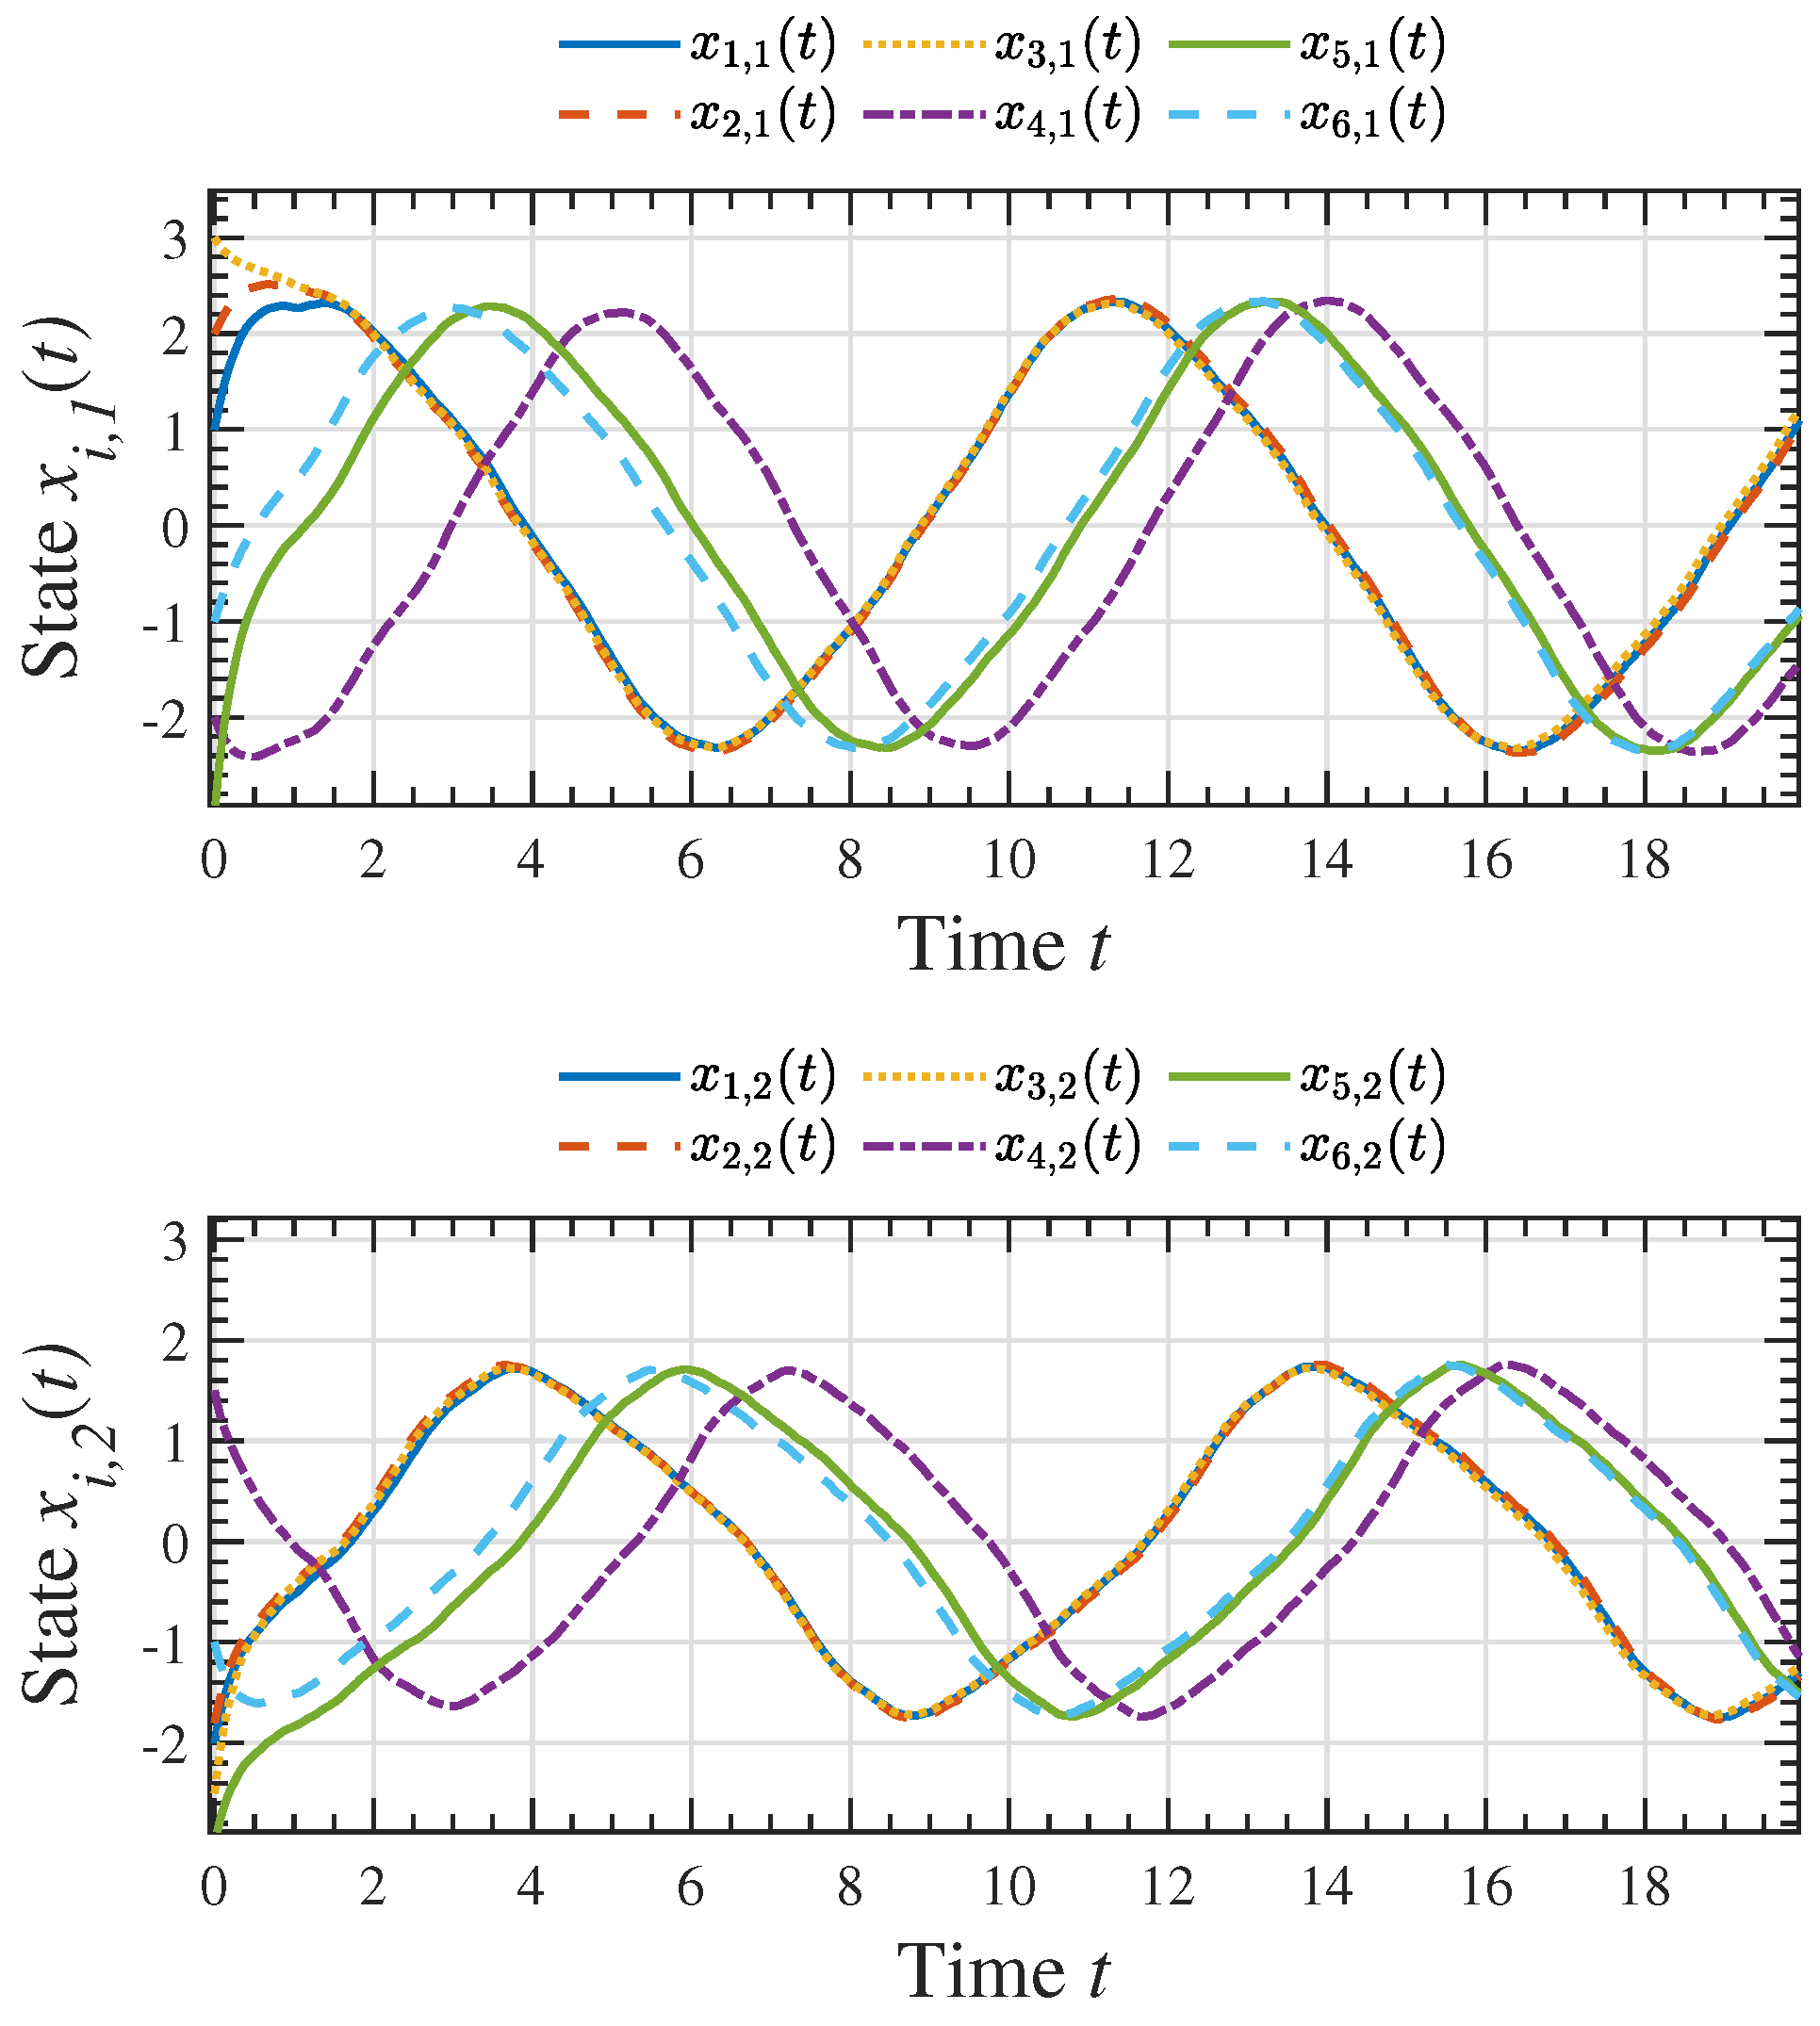
The behavior of the state variables of the network described by Equation (27) without control is shown in Figure 2. From the plot, it is evident that synchronization cannot be achieved by the network’s intrinsic structure alone, indicating that additional intervention is needed to drive the system towards synchronization.
Figure 2.
Trajectories of the state variables of system (27) without control, with fractional order , and initial conditions , , , , , .
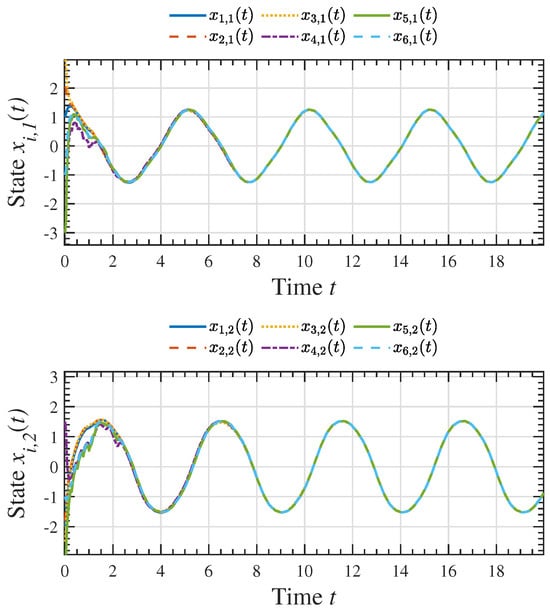
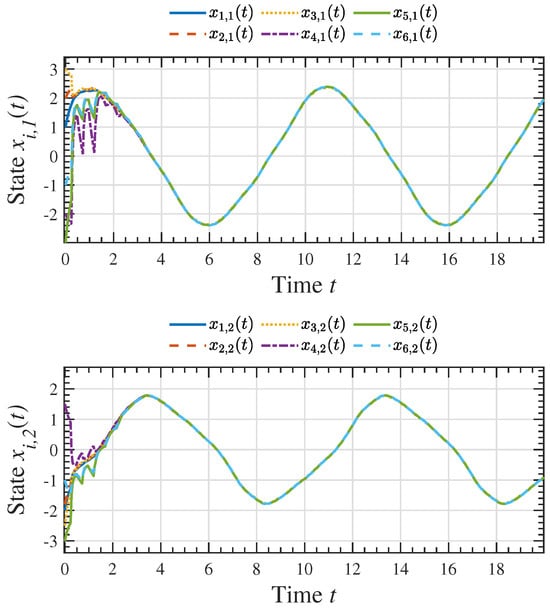
Figure 3 presents the time evolution of the state variables when the system is governed by the controller described in Equation (17). The controlled system shows a significant improvement in the behavior of the state variables, with the trajectories of now moving toward synchronization. This indicates that the applied control mechanism effectively guides the network towards a synchronized state, as compared to the uncontrolled system.
Figure 3.
Trajectories of the state variables of system (27) under the intermittent controller (17), with control gain and threshold function .
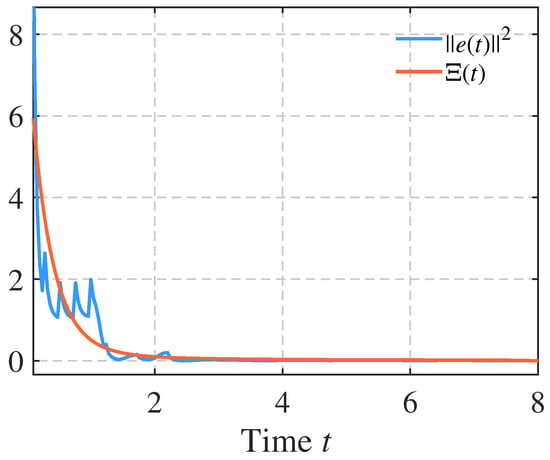
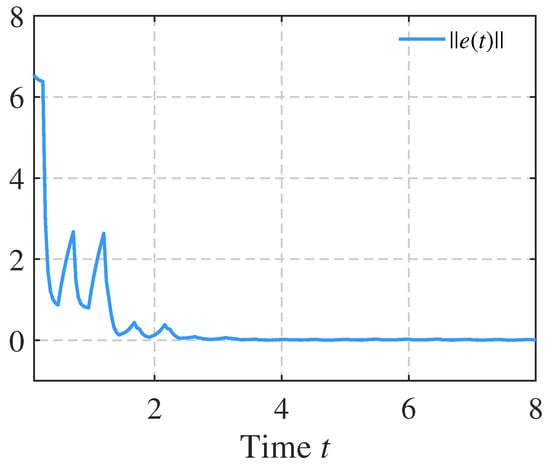
To further analyze the effectiveness of the control, Figure 4 illustrates the trajectories of the error term and the function under the influence of the controller. The error term represents the deviation between the states of the individual nodes, and it can be seen from the figure that this error decreases over time, which suggests that the network’s synchronization is improving. Meanwhile, the function demonstrates the overall system’s performance, further confirming the success of the controller in reducing the error.
Figure 4.
Time responses of the synchronization error and the threshold function under the proposed intermittent controller for system (27).
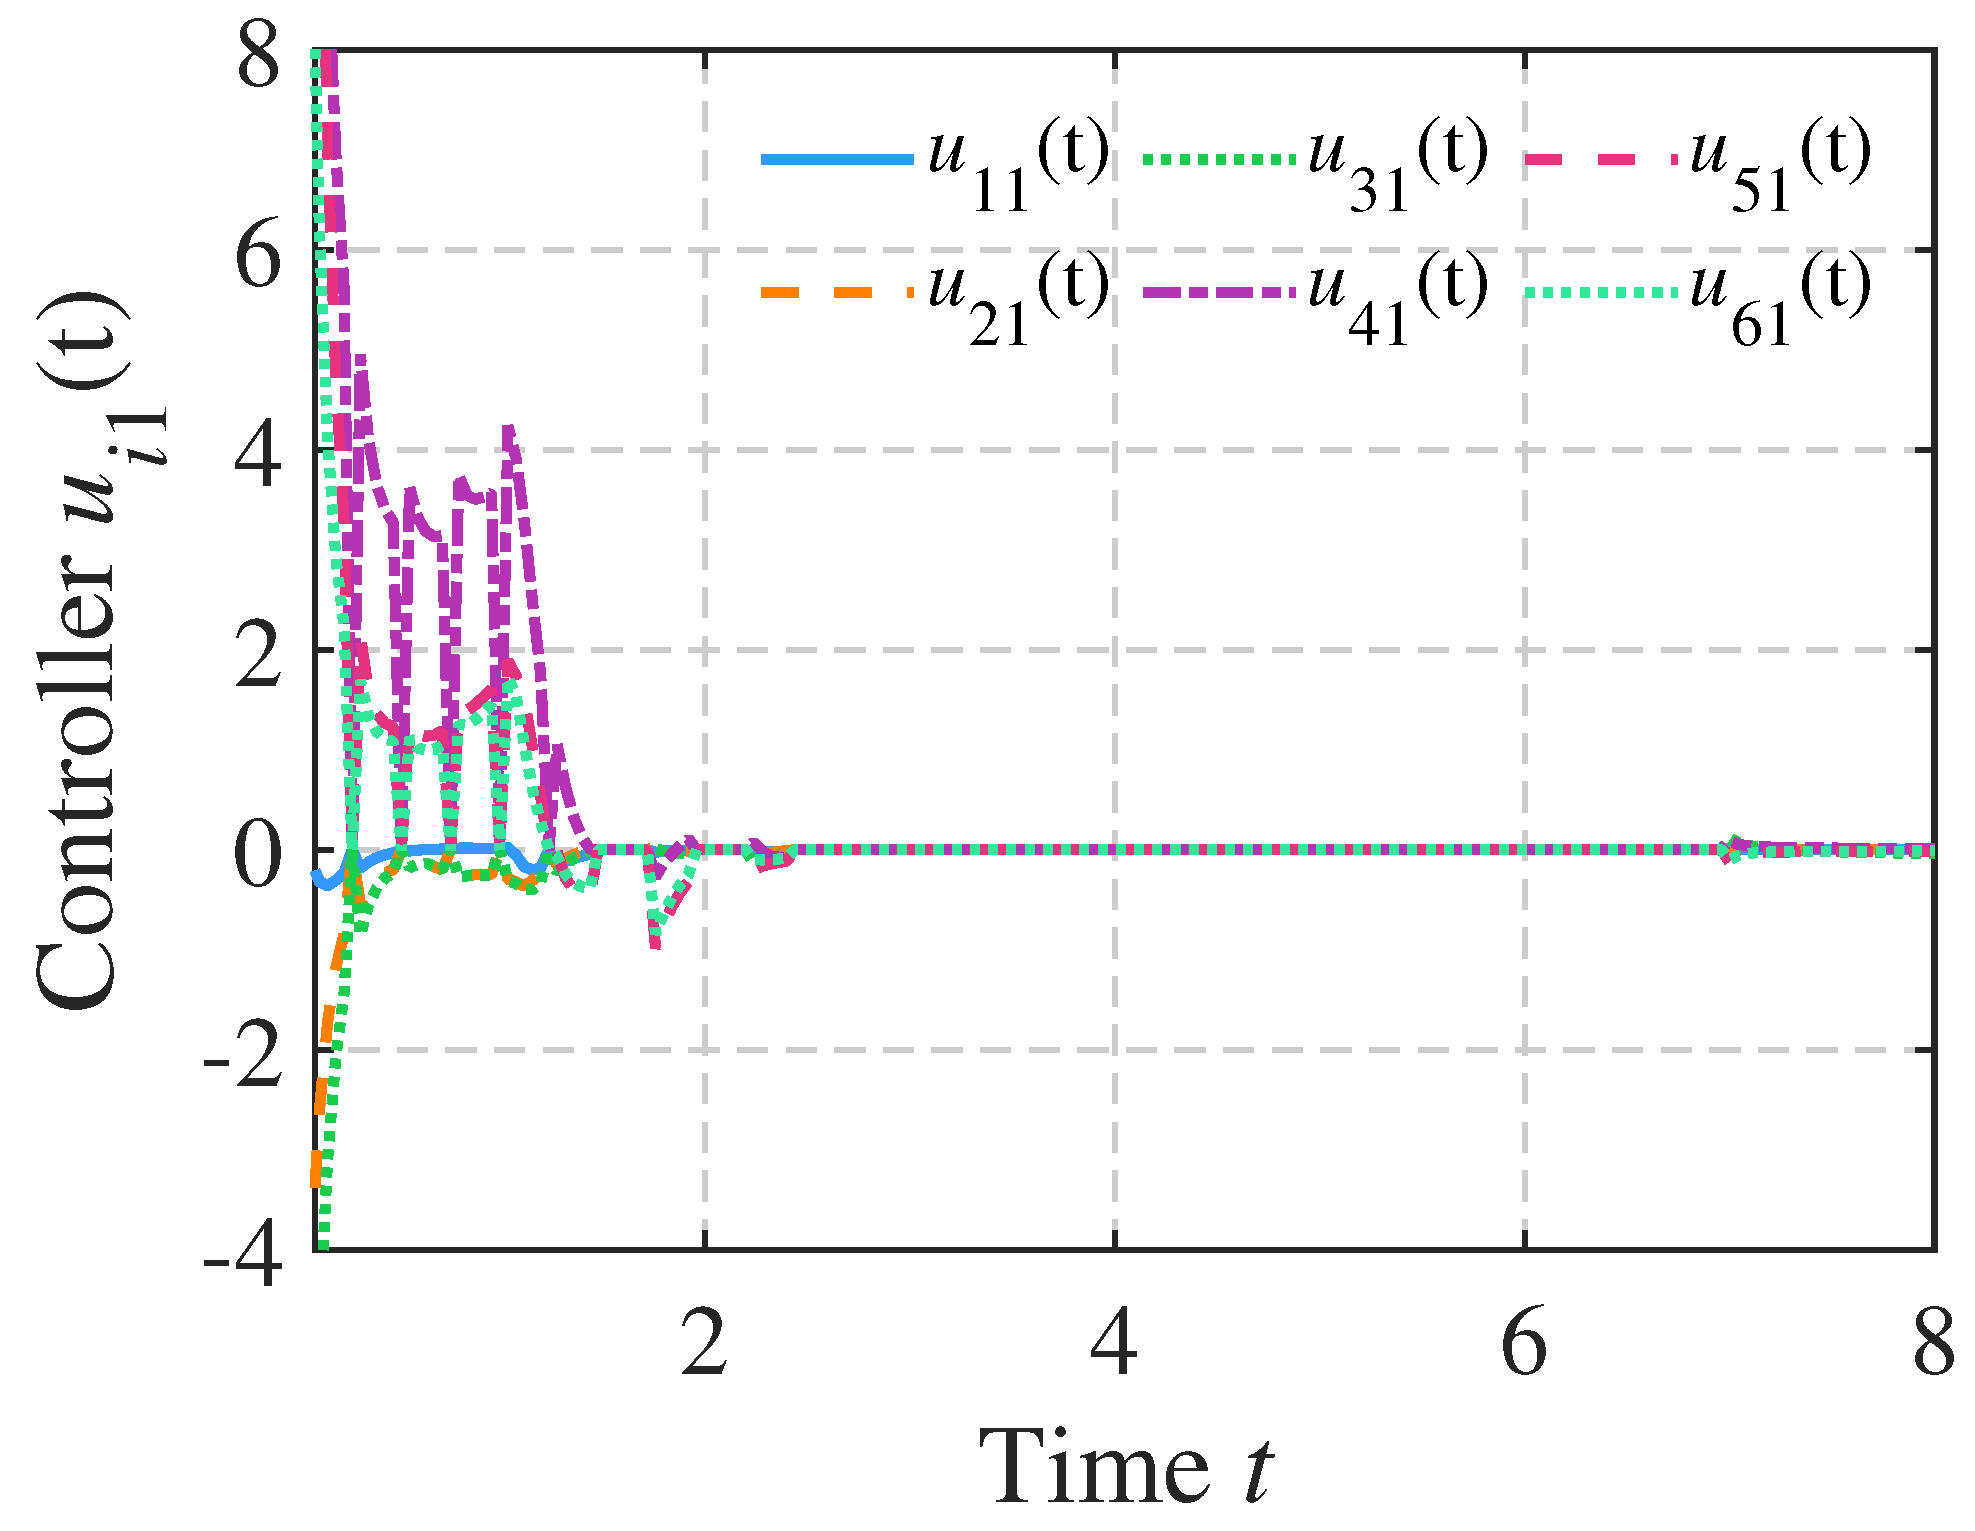
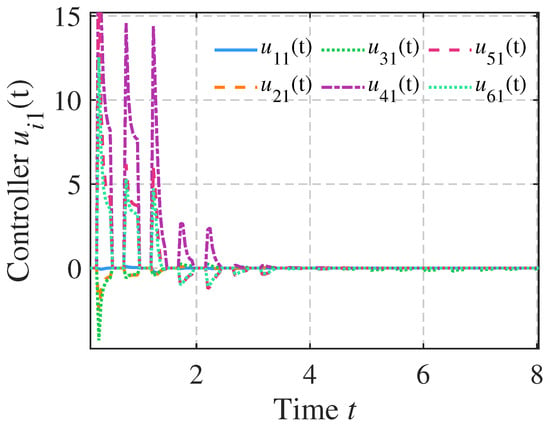
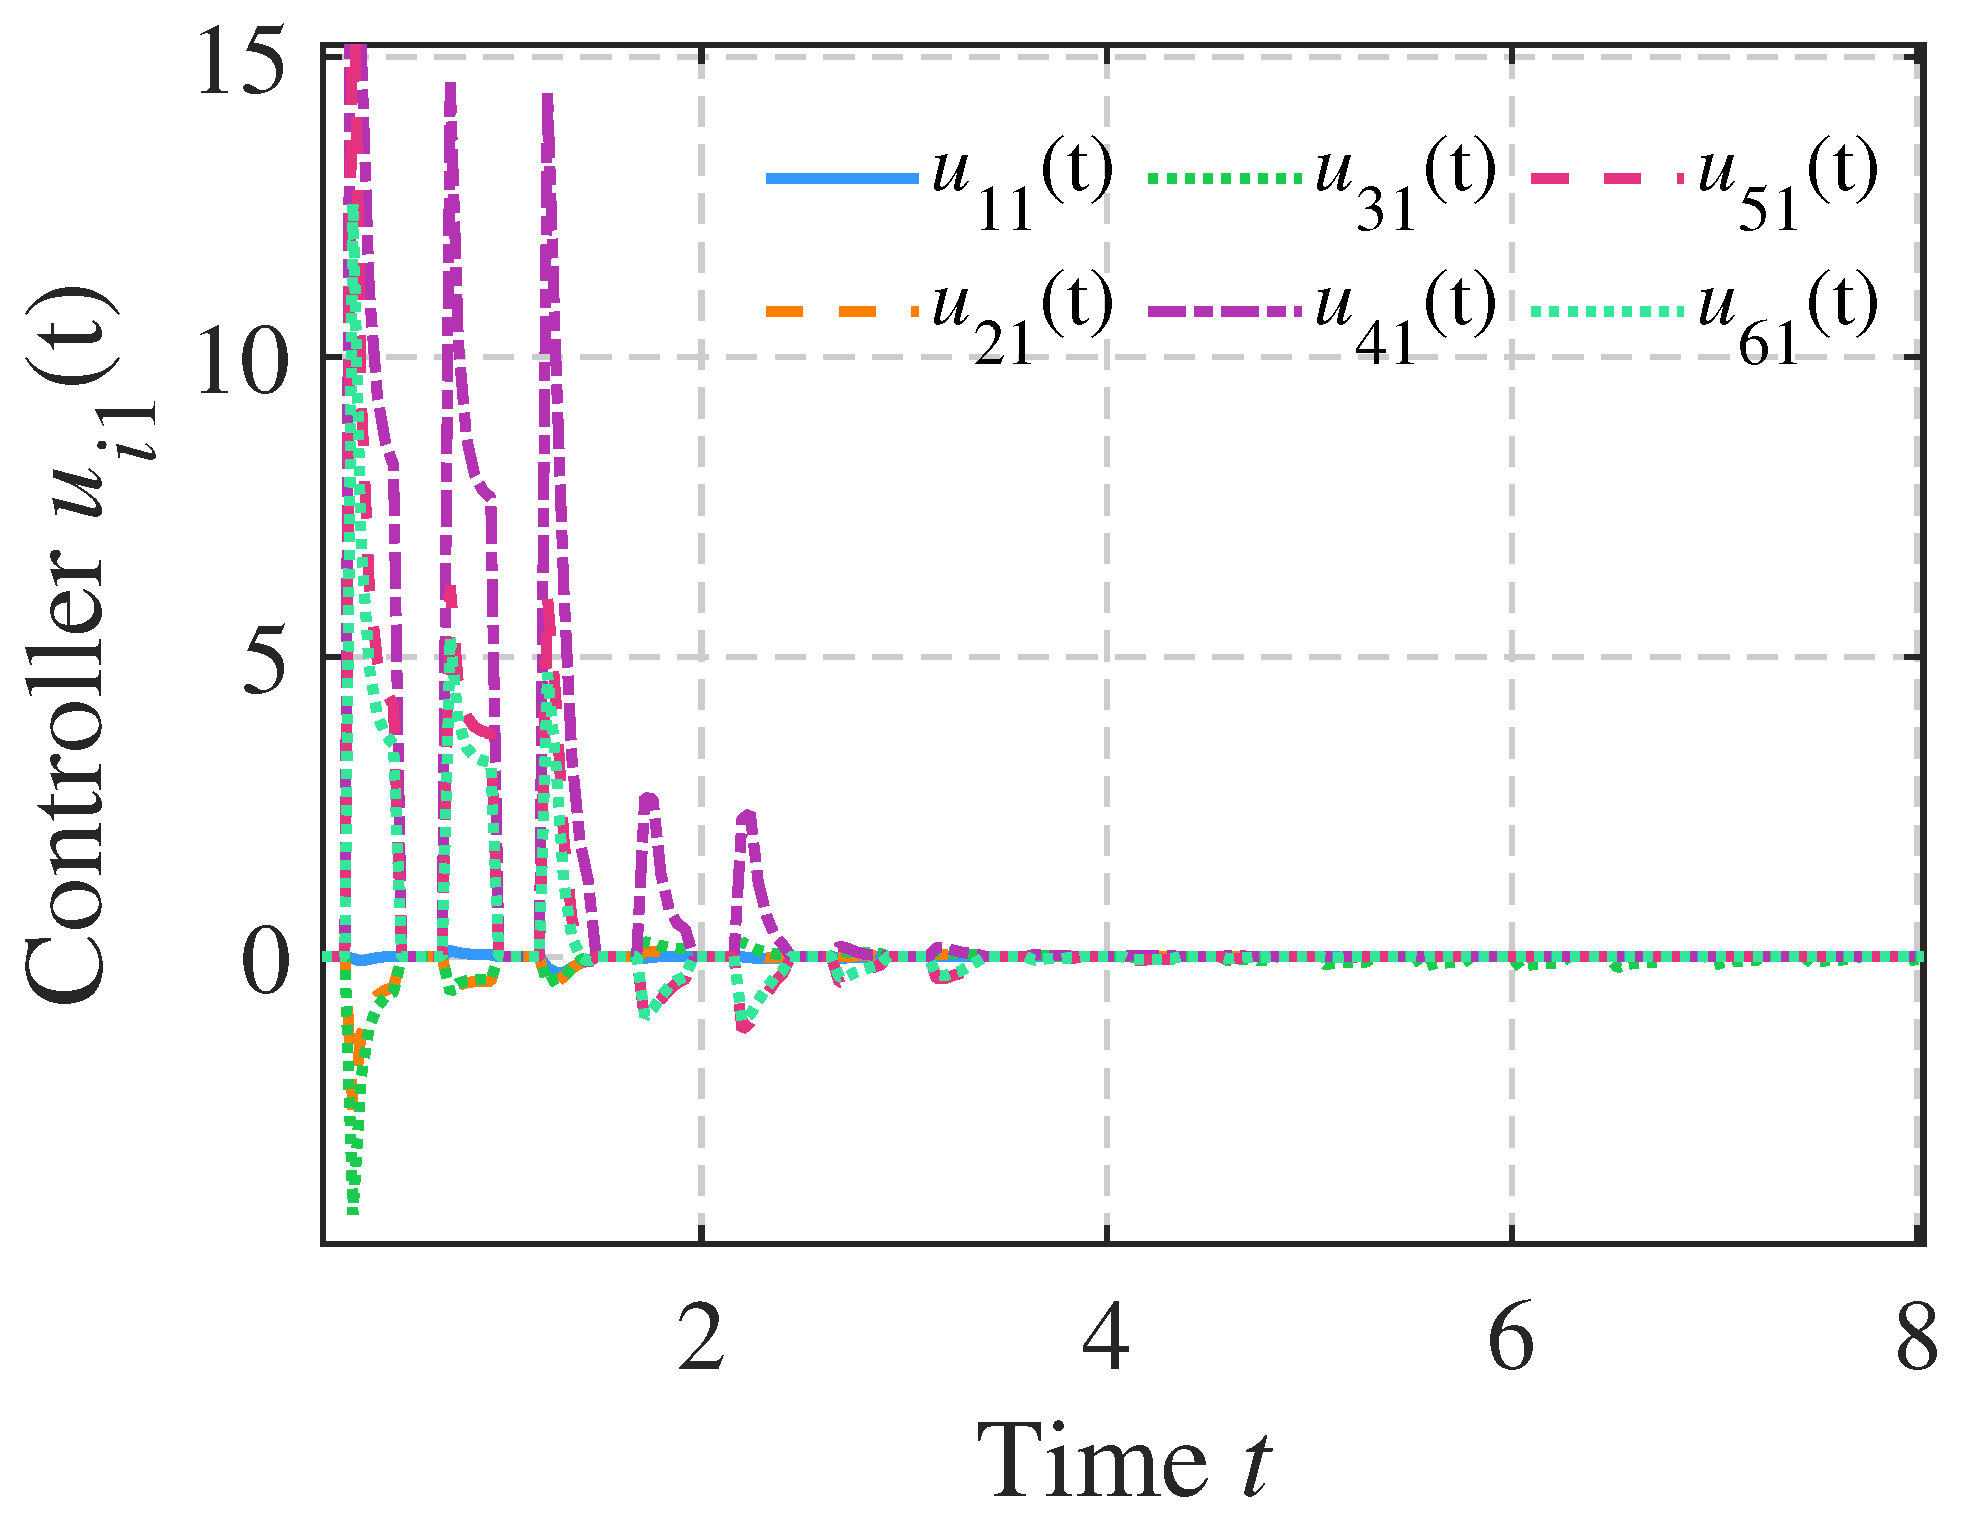
Finally, the time response of the intermittent control, as described by Equation (17), is shown in Figure 5. This figure highlights the dynamic nature of the control process, where the control is applied intermittently to adjust the system’s trajectory. The intermittent application of control provides a more efficient method for synchronization by reducing the overall energy expenditure while still maintaining the necessary adjustments to guide the network towards synchronization.
Figure 5.
Time response of the intermittent control input governed by the controller (17) for system (27).
Example 2.
For the second example, we selected , , , , , while keeping the other system parameters consistent with those in Example 1. The control gain is established by Theorem 2.
The state variable trajectories of the network in Equation (27) without control are shown in Figure 6. It is clear that synchronization cannot be achieved through the network’s intrinsic structure alone, requiring external intervention.
Figure 6.
Trajectories of system (27) for without control in Example 2.
Figure 7 illustrates the time evolution of when the system is controlled by the mechanism in Equation (26). The controlled system shows a notable improvement, with the state variables’ trajectories moving toward synchronization, demonstrating the effectiveness of the control.
Figure 7.
Trajectories of the state variables of system (27) under the intermittent controller (17), with control gain in Example 2.
Figure 8 shows the error term under the controller (24), which decreases over time, indicating improving synchronization in the network. Finally, Figure 9 presents the time response of the intermittent control from Equation (24), emphasizing its dynamic application. The intermittent control method offers a more efficient approach for synchronization, minimizing energy consumption while maintaining necessary adjustments to guide the system toward synchronization.
Figure 8.
Time responses of the synchronization error under the proposed intermittent controller for system (27). in Example 2.
Figure 9.
Time evolution of intermittent control input for system (27) in Example 2.
5. Conclusions
This work demonstrates that incorporating higher-order interactions and mixed delays significantly influences the synchronization behavior of fractional-order coupled neural networks. By developing new analytical tools for fractional systems and an event-dependent intermittent controller, we establish synchronization criteria that reduce control frequency while maintaining stability. The numerical results confirm the effectiveness of these findings. Future research may extend the proposed approach to networks with stochastic disturbances, adaptive event thresholds, or hardware implementation constraints.
Author Contributions
Conceptualization, Z.W., D.Y. and H.L.; methodology, Z.W. and D.Y.; software, Z.W. and X.L.; validation, Y.Y. and P.C.; formal analysis, Z.W., D.Y. and H.L.; investigation, Z.W. and X.L.; resources, Y.Y. and P.C.; writing—original draft preparation, Z.W.; writing—review and editing, D.Y., H.L. and Y.Y.; visualization, Z.W. and X.L. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported in part by the National Natural Science Foundation of China (Grant Nos 12161063, 62173027, 12201175); in part by the Key Project of Inner Mongolia Natural Science Foundation (Grant No. 2025ZD036); in part by the Inner Mongolia Autonomous Region Science and Technology Plan Project (Grant No. 2025KYPT0098); in part by the Youth Top Talent Project of of Hebei Education Department (No. BJK2024125).
Data Availability Statement
The raw data supporting the conclusions of this article will be made available by the authors on request.
Conflicts of Interest
We declare that we have no conflict of interest.
References
- Tian, Y.; Wang, Z. Finite-time extended dissipative filtering for singular T-S fuzzy systems with nonhomogeneous Markov jumps. IEEE Trans. Cybern. 2022, 52, 4574–4584. [Google Scholar] [CrossRef]
- Wang, Z.; Liu, N.; Wang, R. Odor pattern recognition of olfactory neural network based on neural energy. Nonlinear Dyn. 2024, 112, 22421–22438. [Google Scholar] [CrossRef] [Scilit]
- Tian, Y.; Su, X.; Shen, C.; Ma, X. Exponentially extended dissipativity-based filtering of switched neural networks. Automatica 2024, 161, 111465. [Google Scholar] [CrossRef] [Scilit]
- Doria-Cerezo, A.; Olm, J.M.; di Bernardo, M.; Nuño, E. Modelling and control for bounded synchronization in multi-terminal VSC-HVDC transmission networks. IEEE Trans. Circuits Syst. I Reg. Pap. 2016, 63, 916–925. [Google Scholar] [CrossRef]
- Rubenstein, M.; Cornejo, A.; Nagpal, R. Programmable self-assembly in a thousand-robot swarm. Science 2014, 345, 795–799. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhang, Z.; Ma, T. Variable impulsive bipartite coordination control of nonlinear systems with DoS attacks. Nonlinear Dyn. 2025, 113, 8623–8640. [Google Scholar] [CrossRef] [Scilit]
- Wu, G.; Zeng, D.; Baleanu, D. Fractional impulsive differential equations: Exact solutions, integral equations and short memory case. Fract. Calc. Appl. Anal. 2019, 22, 180–192. [Google Scholar] [CrossRef] [Scilit]
- Wu, G.; Deng, Z.; Baleanu, D.; Zeng, D. New variable-order fractional chaotic systems for fast image encryption. Chaos 2019, 29, 083103. [Google Scholar] [CrossRef] [Scilit]
- Baleanu, D.; Wu, G. Some further results of the Laplace transform for variable-order fractional difference equations. Fract. Calc. Appl. Anal. 2019, 22, 1641–1654. [Google Scholar] [CrossRef] [Scilit]
- Liu, D.; Zhao, S.; Luo, X.; Yuan, Y. Synchronization for fractional-order extended Hindmarsh-Rose neuronal models with magneto-acoustical stimulation input. Chaos Solitons Fractals 2021, 141, 110635. [Google Scholar] [CrossRef] [Scilit]
- Song, C.; Cao, J. Dynamics in fractional-order neural networks. Neurocomputing 2014, 142, 494–498. [Google Scholar] [CrossRef] [Scilit]
- Sacu, I. Effects of high-order interactions on synchronization of a fractional-order neural system. Cogn. Neurodyn. 2024, 18, 1877–1893. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- He, H.; Jiang, N.; Liu, X.; Fan, L. Impulsive synchronization and parameter optimization for disturbed inertial memristive neural networks with actuator saturation. Phys. A 2025, 674, 130755. [Google Scholar] [CrossRef] [Scilit]
- Boya, B.; Ramakrishnan, B.; Effa, J.; Kengne, J.; Rajapopal, K. The effects of symmetry breaking on the dynamics of an inertial neural system with a non-monotonic activation function: Theoretical study, asymmetric multistability and experimental investigation. Phys. A 2022, 602, 127458. [Google Scholar] [CrossRef] [Scilit]
- Maximo, J.O.; Armstrong, W.P.; Kraguljac, N.V.; Lahti, A.C. Higher-order intrinsic brain network trajectories after antipsychotic treatment in medication-naive patients with first-episode psychosis. Biol. Psychiatry 2024, 96, 198–206. [Google Scholar] [CrossRef] [Scilit]
- Liu, D.; Zhang, B.; Wang, B. Inverse optimal pinning synchronization control for higher-order networks on multi-directed hypergraphs. Chaos Solitons Fractals 2025, 199, 116593. [Google Scholar] [CrossRef] [Scilit]
- Zhao, N.; Zhang, X. Impact of higher-order interactions on amplitude death of coupled oscillators. Phys. A 2023, 622, 128803. [Google Scholar] [CrossRef] [Scilit]
- Singh, A.; Verma, U.K.; Mishra, A.; Yadav, K.; Sharma, A.; Varshney, V. Higher-order interaction in multiplex neuronal networks with electric and synaptic coupling. Chaos Solitons Fractals 2024, 182, 114864. [Google Scholar] [CrossRef] [Scilit]
- Mehrabbeik, M.; Jafari, S.; Perc, M. Synchronization in simplicial complexes of memristive Rulkov neurons. Front. Comput. Neurosci. 2023, 17, 1248976. [Google Scholar] [CrossRef] [Scilit]
- Farrera-Megchun, A.; Padilla-Longoria, P.; Santos, G.J.; Espinal-Enriquez, J.; Bernal-Jaquez, R. Explosive synchronization driven by repulsive higher-order interactions in coupled neurons. Chaos Solitons Fractals 2025, 196, 114864. [Google Scholar] [CrossRef] [Scilit]
- Xu, Y.; Jiang, Z.; Xie, X.; Li, W.; Wu, Y. Fuzzy-based bipartite quasi-synchronization of fractional-order heterogeneous reaction-diffusion neural networks via intermittent control. IEEE Trans. Circuits Syst. I Reg. Pap. 2024, 71, 3880–3890. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.; Guo, Z.; Xue, L.; Ahn, C.K.; Liu, J. Stabilization of complex networks under asynchronously intermittent event-triggered control. Automatica 2024, 161, 111493. [Google Scholar] [CrossRef] [Scilit]
- Liu, Y.; Li, Y.M.; Wang, J.L. Intermittent control to stabilization of stochastic highly nonlinear coupled systems with multiple time delays. IEEE Trans. Neural Netw. Learn. Syst. 2023, 34, 4674–4686. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sang, H.; Zhao, J. Exponential synchronization and L2-gain analysis of delayed chaotic neural networks via intermittent control with actuator saturation. IEEE Trans. Neural Netw. Learn. Syst. 2019, 30, 3722–3734. [Google Scholar] [CrossRef] [Scilit]
- Ding, S.; Wang, Z.; Rong, N. Intermittent control for quasi-synchronization of delayed discrete-time neural networks. IEEE Trans. Cybern. 2020, 51, 862–873. [Google Scholar] [CrossRef] [Scilit]
- Xue, L.; Zhou, H.; Wu, Y. Aperiodically intermittent dynamic event-triggered control for predefined-time synchronization of stochastic complex networks. IEEE Trans. Netw. Sci. Eng. 2025, 12, 970–981. [Google Scholar] [CrossRef] [Scilit]
- Hu, X.; Wang, L.; Zong, X. Fixed-time event-dependent intermittent control for reaction-diffusion systems. Int. J. Robust Nonlinear Control 2024, 34, 10331–10345. [Google Scholar] [CrossRef] [Scilit]
- Ding, S.; Wang, Z. Synchronization of coupled neural networks via an event-dependent intermittent pinning control. IEEE Trans. Syst. Man Cybern. Syst. 2022, 52, 1928–1934. [Google Scholar] [CrossRef] [Scilit]
- Song, C.; Zhou, J.; Wang, J. Finite-time inter-layer synchronization of duplex networks via event-dependent intermittent control. IEEE Trans. Circuits Syst. II Express Briefs 2022, 69, 4889–4893. [Google Scholar] [CrossRef] [Scilit]
- Liu, X.; Wu, K.; Ahn, C. Intermittent boundary control for synchronization of fractional delay neural networks with diffusion terms. IEEE Trans. Syst. Man Cybern. Syst. 2023, 53, 2900–2912. [Google Scholar] [CrossRef] [Scilit]
- Chen, R.; Li, H.; Liu, H.; Jiang, H.; Cao, J. Complete synchronization of discrete-time fractional-order T-S fuzzy complex-valued neural networks with time delays and uncertainties. IEEE Trans. Fuzzy Syst. 2025, 33, 842–856. [Google Scholar] [CrossRef] [Scilit]
- Liu, X.; Yu, Y. Discrete fractional-order Halanay inequality with mixed time delays and applications in discrete fractional-order neural network systems. Fract. Calc. Appl. Anal. 2025, 28, 1384–1403. [Google Scholar] [CrossRef] [Scilit]
- Wei, C.; Wang, X.; Hui, M.; Zeng, Z. Quasi-synchronization of fractional multiweighted coupled neural networks via aperiodic intermittent control. IEEE Trans. Cybern. 2023, 54, 1671–1684. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Podlubny, I. Fractional Differential Equations; Academic Press: San Diego, CA, USA, 1999. [Google Scholar]
- Liu, P.; Zeng, Z.; Wang, J. Multiple Mittag-Leffler stability of fractional-order recurrent neural networks. IEEE Trans. Syst. Man Cybern. Syst. 2017, 47, 2279–2288. [Google Scholar] [CrossRef] [Scilit]
- Duffy, D.G. Transform Methods for Solving Partial Differential Equations; Chapman and Hall/CRC: New York, NY, USA, 2004. [Google Scholar]
- Boyd, S.; Ghaoui, L.; Feron, E. Linear Matrix Inequalities in System and Control Theory; SIAM: Philadelphia, PA, USA, 1994. [Google Scholar]
- Liu, P.; Wang, J.; Zeng, Z. Fractional-order vectorial Halanay-type inequalities with applications for stability and synchronization analyses. IEEE Trans. Syst. Man Cybern. Syst. 2022, 53, 1573–1583. [Google Scholar] [CrossRef] [Scilit]
- Zhou, J.; Li, B.; Lu, J.; Shi, D. Selection of simplexes in pinning control of higher-order networks. Sci. Sin. Inf. 2024, 54, 708–716. [Google Scholar] [CrossRef] [Scilit]
- Gambuzza, L.; Patti, F.; Gallo, L.; Lepri, S.; Romance, M.; Criado, R.; Frasca, M.; Latora, V.; Boccaletti, S. Stability of synchronization in simplicial complexes. Nat. Commun. 2021, 12, 1255. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.; Zhong, J.; Lu, J. Intermittent control for finite-time synchronization of fractional-order complex networks. Neural Netw. 2021, 144, 11–20. [Google Scholar] [CrossRef] [Scilit]
- Xu, Y.; Gao, S.; Li, W. Exponential stability of fractional-order complex multi-link networks with aperiodically intermittent control. IEEE Trans. Neural Netw. Learn. Syst. 2020, 32, 4063–4074. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).