


Abstract
This paper investigates the tracking problem of fractional-order multi-agent systems. Both the order and parameters of the leader are unknown. Firstly, based on the positive system approach, the asymptotically stable criteria for incommensurate linear fractional-order systems are derived. Secondly, the models of incommensurate heterogeneous multi-agent systems are introduced. To cope with incommensurate and heterogeneous situations among followers and the leader, radial basis function neural networks (RBFNNs) and a discontinuous control method are used. Thirdly, the consensus criteria are derived by using the Vector Lyapunov Function method. Finally, a numerical example is presented to illustrate the effectiveness of the proposed theoretical method.
1. Introduction
In recent decades, consensus problems have attracted many people’s attention due to their applications in many fields such as social sciences, physics, control engineering, etc. Consensus of integer-order multi-agent systems (MASs) have been studied in many earlier studies [1,2,3,4,5]. However, there are numerous phenomena that cannot be adequately described by integer-order dynamics, for instance, the synchronized motion of agents in fractional circumstances, like macromolecule fluids and porous media. Consequently, consensus of fractional-order multi-agent systems (FOMASs) were first studied in [6]. In the past decade, FOMASs have attracted much attention, becoming a hot topic in the field of cooperative control [7,8,9,10].
Due to the diversity of each agent, the parameters of every individuality may not be identical, thus called heterogeneous. There are many studies about first-order, second-order or high-order MASs, which have heterogeneous dynamics among their agents [11,12,13,14]. Among these, the complete consensus is difficult to achieve by using static linear feedback control protocol. If the MASs have fractional-order (FO) dynamics, there are also some studies that are similar to those of the integer-order cases [15,16,17,18,19,20]. Note that orders of systems are also parameters in the FOMASs, and the incommensurate order is a distinctive feature of heterogeneous FOMASs. However, there are few studies about FOMASs with different order individualities. In [21], the problem of finite-time consensus tracking for incommensurate nonlinear FOMASs has been investigated, where the communication topology of the MASs is directed and switched. In [22], the problem of practical fixed-time bipartite consensus of a nonlinear incommensurate FOMAS via sliding-mode technique has been discussed, which has a general communication network with a signed directed graph. The above studies promote the finite-time stability theory of incommensurate order FO systems. But the orders of the leader in the above studies are known. In [23], consensus control of incommensurate FOMASs with nonlinear and uncertain dynamics has been studied, in which, the order of the leader is unknown, and the authors have built an analysis frame about the consensus problem of incommensurate systems. However, only bounded consensus has been achieved in the paper.
This manuscript tries to address the tracking problem of heterogeneous FOMASs, in which both the orders and parameters of the leader are unknown. The radial basis function neural networks (RBFNNs) are designed to estimate the errors of the states among different orders, which help to establish the error dynamical equations. Furthermore, the Vector Lyapunov Function method is applied to analyze the stability of the error system. In summary, the contributions of this paper are the following: (1) Based on a positive system approach, the asymptotically stable criteria for incommensurate linear FO systems are derived, and some discussion about the existing literature has been presented. (2) A multi-agent system with incommensurate orders and parameters is used to track the leader with unknown order and parameters, and complete consensus can be achieved under the controllers in this manuscript. (3) An analysis frame of leader-following consensus is established by using the Vector Lyapunov Function method.
The main structure of the remaining part of this paper is organized as follows. In Section 2, some fundamental definitions and lemmas of FO calculus are introduced, and the asymptotic stability of the positive incommensurate FO system is presented. The incommensurate heterogeneous FOMASs and the problem in this paper will be formally stated in Section 3. The main results about sufficient conditions of consensus of the considered FOMASs are presented in Section 4. In Section 5, a simulation example is given to check the theoretical results. Finally, concluding remarks are presented in Section 6.
Notations: Let be the set of natural integers. Let be the set of real numbers. and refer to the n-dimensional real vector and real matrices. Let () be n-dimensional real vector with non-negative elements. If , , then denotes . The superscript “T” denotes matrix transposition. denotes the n-dimensional identity matrix. For a vector , is defined as , and is defined as . For , and represents the maximum and minimum eigenvalue of P, respectively.
2. Fractional-Order Calculus with Caputo’s Operator
In this subsection, some preliminary knowledge of FO calculus is introduced first. Then, some introductions about the Mittag–Leffler function are introduced, which will be used in later sections. After which, the asymptotic stability of the positive incommensurate FO system is analyzed.
Definition 1
([24]). For a continuous function : , the FO integral of order is defined by
Definition 2
([24]). Let function be differentiable on ; the Caputo FO derivative of order for is defined as
Lemma 1
([24]). Let for or for . If , then
In particular, if and , then
Lemma 2
([25]). If a vector function is derivable on , we have the following inequality:
where , and is a constant positive definite matrix.
In FO calculus, the Mittag–Leffler function is significant, let . The following differentiation formula is an immediate consequence of the definition of the Mittag–Leffler function .
Lemma 3.
Let ; then, . Consequently, let ; then, ; let ; then, , where , , are constants and in , , in .
Proof.
According to the definition of and the property of that , one has
Let ; then, . Let ; then, . This completes our proof. ☐
The Vector Lyapunov Function method will be the main tool in this paper. The analysis of the asymptotic stability of the positive incommensurate FO system is presented in the following Lemma. Considering the autonomous linear incommensurate FO system, in this paper, we assume the initial time as :
where , , , .
Lemma 4
([26]). Assume that the A is a Metzler matrix and also a Hurwitz matrix. Then, there exists such that .
Lemma 5.
Assume that R is a Metzler matrix and also a Hurwitz matrix; then, the system (1) is asymptotically stable for any .
Proof.
The system can be represented by components as the following:
Then, according to the theory of solution for nonhomogeneous linear FO differential equations (one can see Section 3.2 (pp. 54–56) of [27]), it is easy to obtain
where
Integrating by parts, we obtain
According to Lemma 4, one can conclude that there must be an , which is satisfied by . By some simple calculations and using Lemma 3, we have
When , one can obtain , . Then,
According to the system, one has
i.e.,
one can conclude that
Assume that there is a such that and when . Based on (3), we have
which is contradictory; thus, , . Consequently, is monotonically non-increasing and .
Thus, one can conclude that is existent and finite; assuming that , one has with . Based on the Final Value Theorem of Laplace Transform, we have and , where denotes the Laplace Transform of a function. Let and ; then,
which implies that ; combined with R in nonsingular, one can obtain with any initial condition . ☐
Remark 1.
Indeed, the above Lemma is a special case of Lemma 3 in [28]. In [28], to prove is monotonically non-increasing, the authors assume and then derive by analyzing FO system . However, according to the definition of FO derivatives,
In general,
Consequently, the proof of Lemma 3 in [28] may not appropriate. Based on the above Lemma, we have proved the monotonically non-increasing nature of via directly.
3. Preliminaries and Problem Formulation
3.1. Algebraic Graph Theory
In this subsection, we introduce some fundamental definitions pertaining to algebraic graph theory, which will serve as the basis for subsequent sections.
Let be a graph with N nodes, where , denote the set of nodes and edges, respectively. is a weighted adjacency matrix, where , if and ; otherwise, for all . The corresponding Laplacian matrix L is defined as if and .
3.2. System Model
In this subsection, the model of FOMASs will be introduced, and the problem formulation will be given. Considering the following heterogeneous FOMAS consists of N agents with different orders, the FO dynamical model of the ith agent is described as follows:
where is the state of the ith agent, is the order of the ith agent, is a nonlinear vector value function, is control input or the communication protocol of the ith agent, which would be designed later, and and are constant matrices. is assumed to satisfy the following Lipschitz condition throughout this paper:
Assumption 1.
There are constants , such that, for any ,
Remark 2.
Let . Then, for any diagonal matrices , according to the Assumption 1, one has
Furthermore, the above assumption is mild, which is fitted for many systems, such as Lorenz’s systems and Hopfield neural network systems, etc.
The leader with unknown order is described as follows:
where is the unknown order, and and are also unknown. In this paper, the is designed as follows:
Let error signal ; one has
Let ; then, by some simple derivation, one can obtain the following error dynamic equation:
where , .
Assumption 2.
The is bounded.
According to the above assumption and Assumption 1, one can conclude that is also bounded, i.e., there are constants and such that , , , where denotes the Euclidean norm of a vector.
Lemma 6
([29]). If is a continuous function over a compact set , then there is a RBFNN such that
where is a prescribed accuracy, and the ideal weight vector ψ satisfies
and represents the approximation error, indicates the weight vector, in which being the number of the RBFNN nodes, and is the basis function vector with
where stands for the center vector, and is the width of the Gaussian function.
Lemma 7
([30]). The FO continuous-time system is positive if and only if A is a Metzler matrix, where , are state and input vectors, , , , .
4. Main Results
In this section, the analysis of consensus tracking for the systems (5) and (6) under the protocol (7) is presented.
Theorem 1.
If Assumptions 1 and 2 hold, then the consensus tracking of the heterogeneous FOMAS (5) and (6) could be achieved if there are diagonal matrix , constants such that
where , and have been mentioned in Remark 1, .
Proof.
Consider the Vector Lyapunov Function
where , . Denoting the fractional derivative on the time t of with order along with (8) as , one has
Due to , based on the Cauchy inequality(i.e., ) and the definition of the function , it is easy to obtain
According to Lemma 6, one can conclude that there must be , such that
where , . Then, we have
where , , in which, denotes the Frobenius norm of matrix . Moreover, has been used. According to the Remark 2 and (9), one can obtain
Noting that and when , and , then
It is easy to obtain
Let be the matrix with , for . Let
Then, we have
There must be such that . Consider the following FO auxiliary system
Let . One has
From (10) and , is a Metzler matrix. According to Lemma 7, one has , , i.e., . Based on Lemma 5, it is easy to conclude that the solution of (16) is asymptotically stable, which implies that . Consequently, one has . Because and P is a positive definite matrix, , , i.e., ; then, the tracking consensus of the FOMAS (5) and (6) can be achieved, which completes our proof. ☐
5. Numerical Simulations
Consider a heterogeneous incommensurate FOMAS with four followers: , where , , and
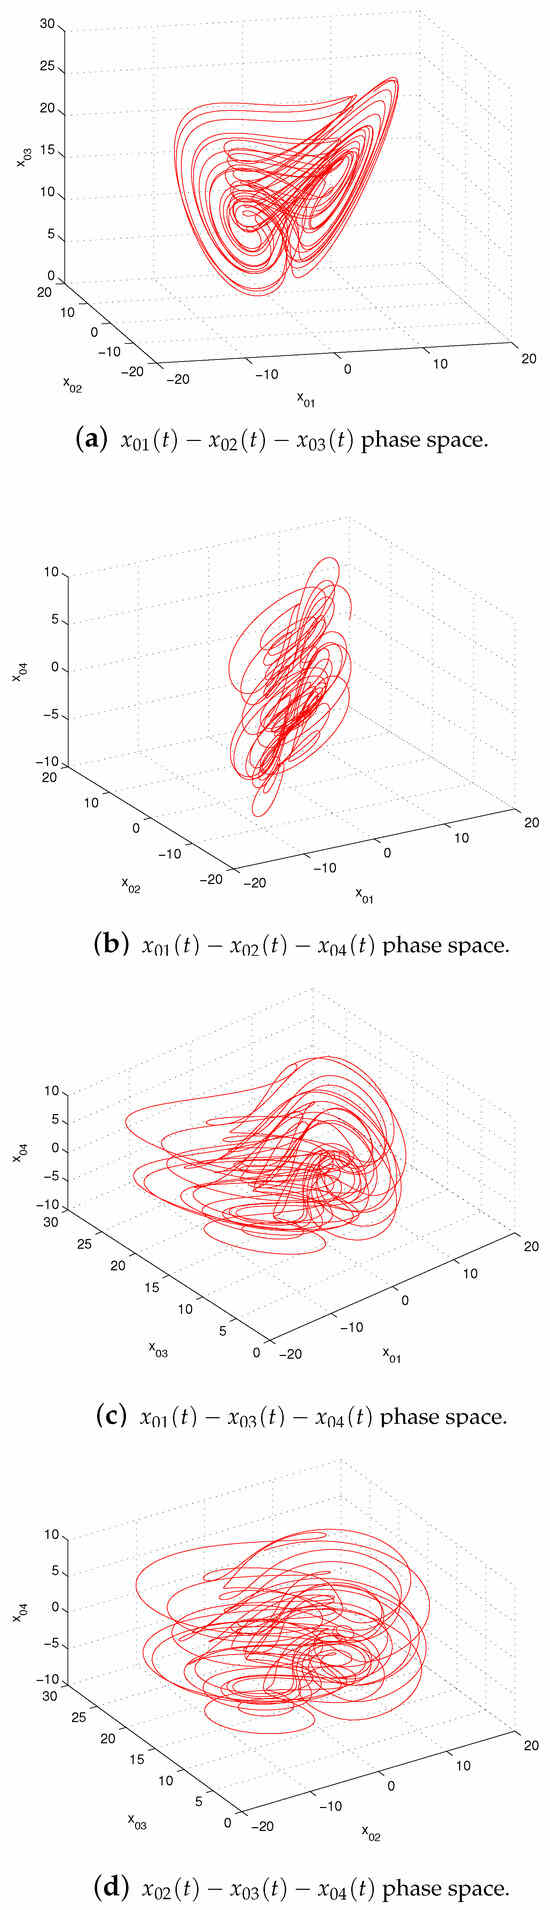
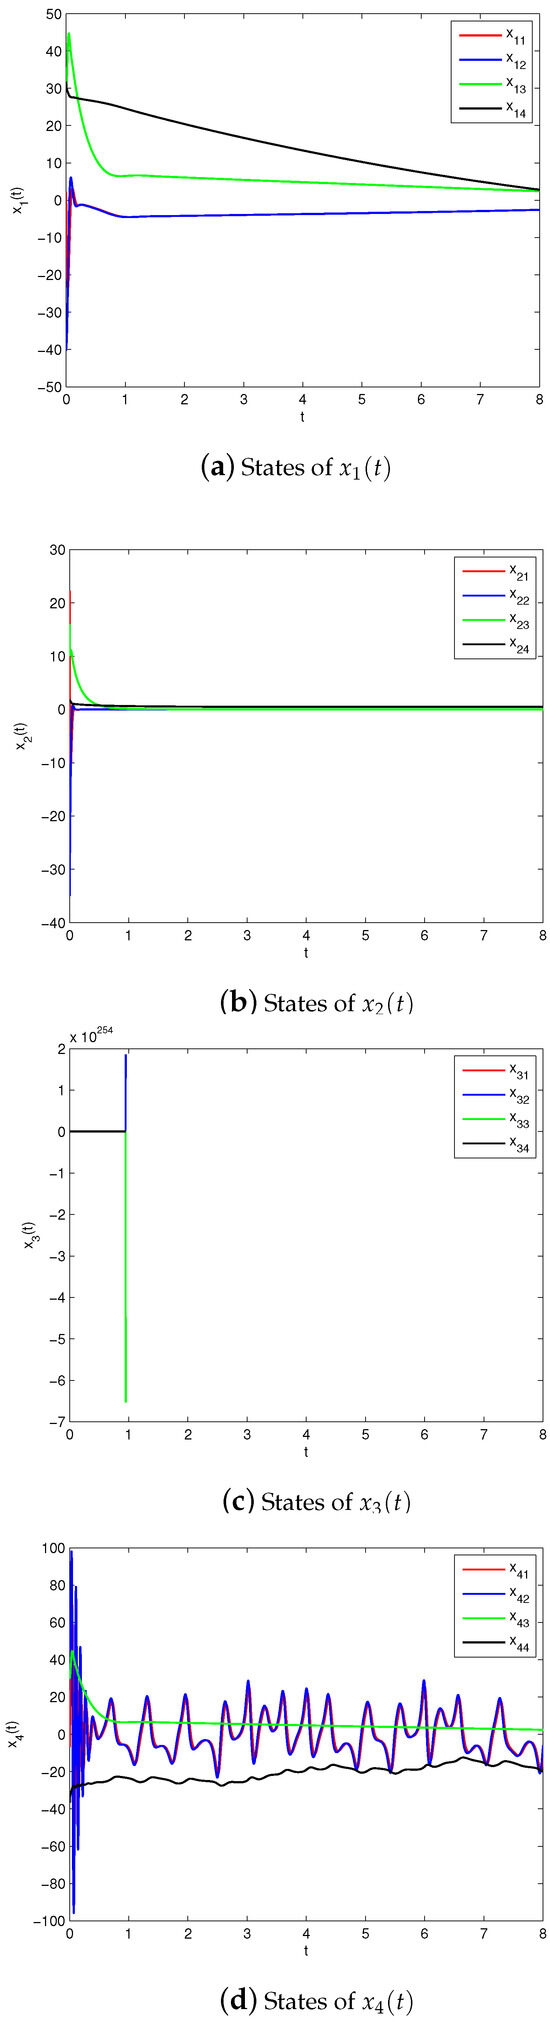
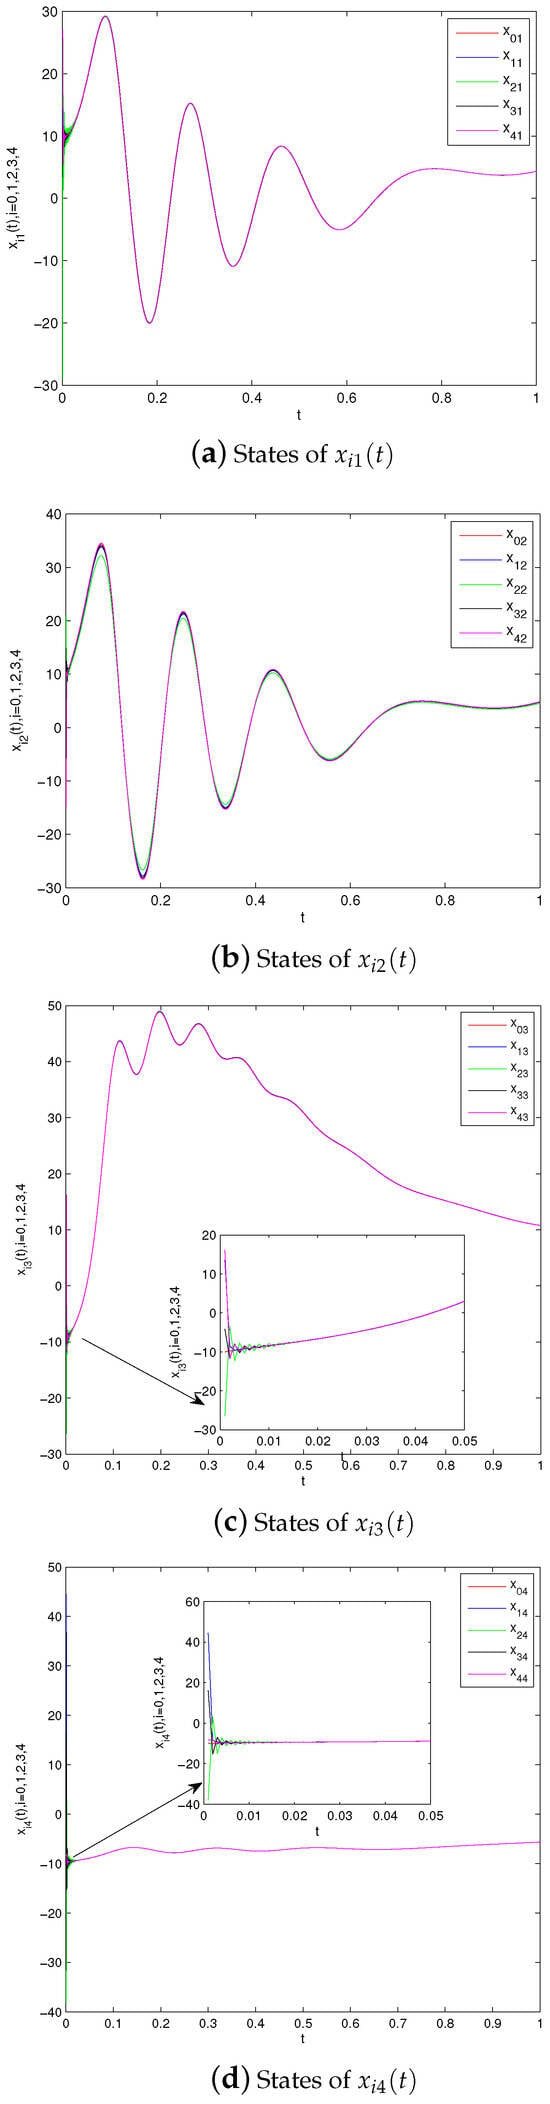
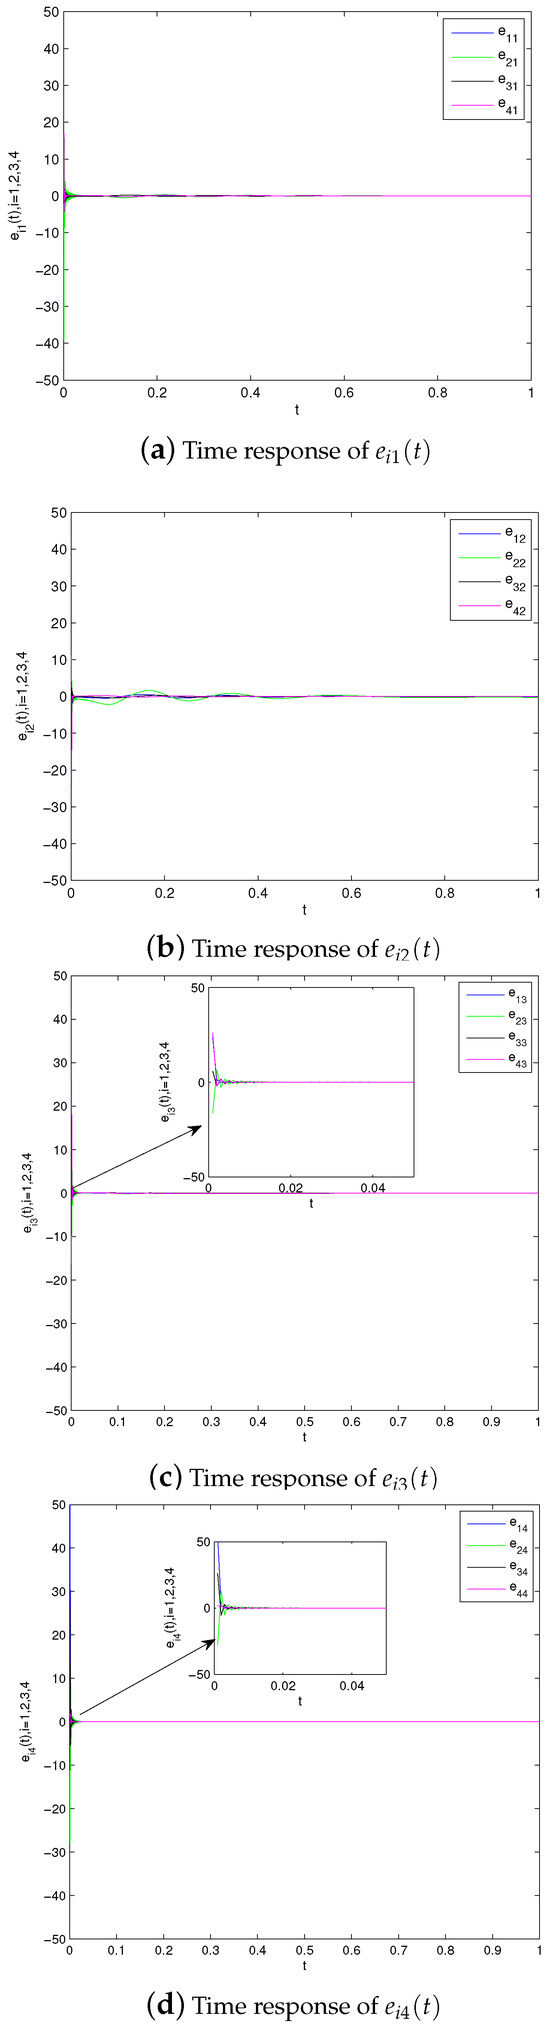
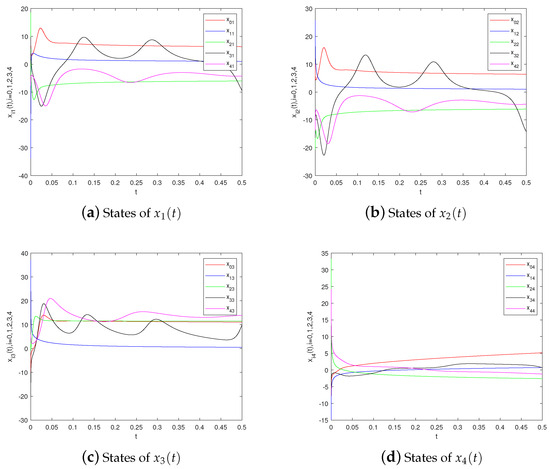
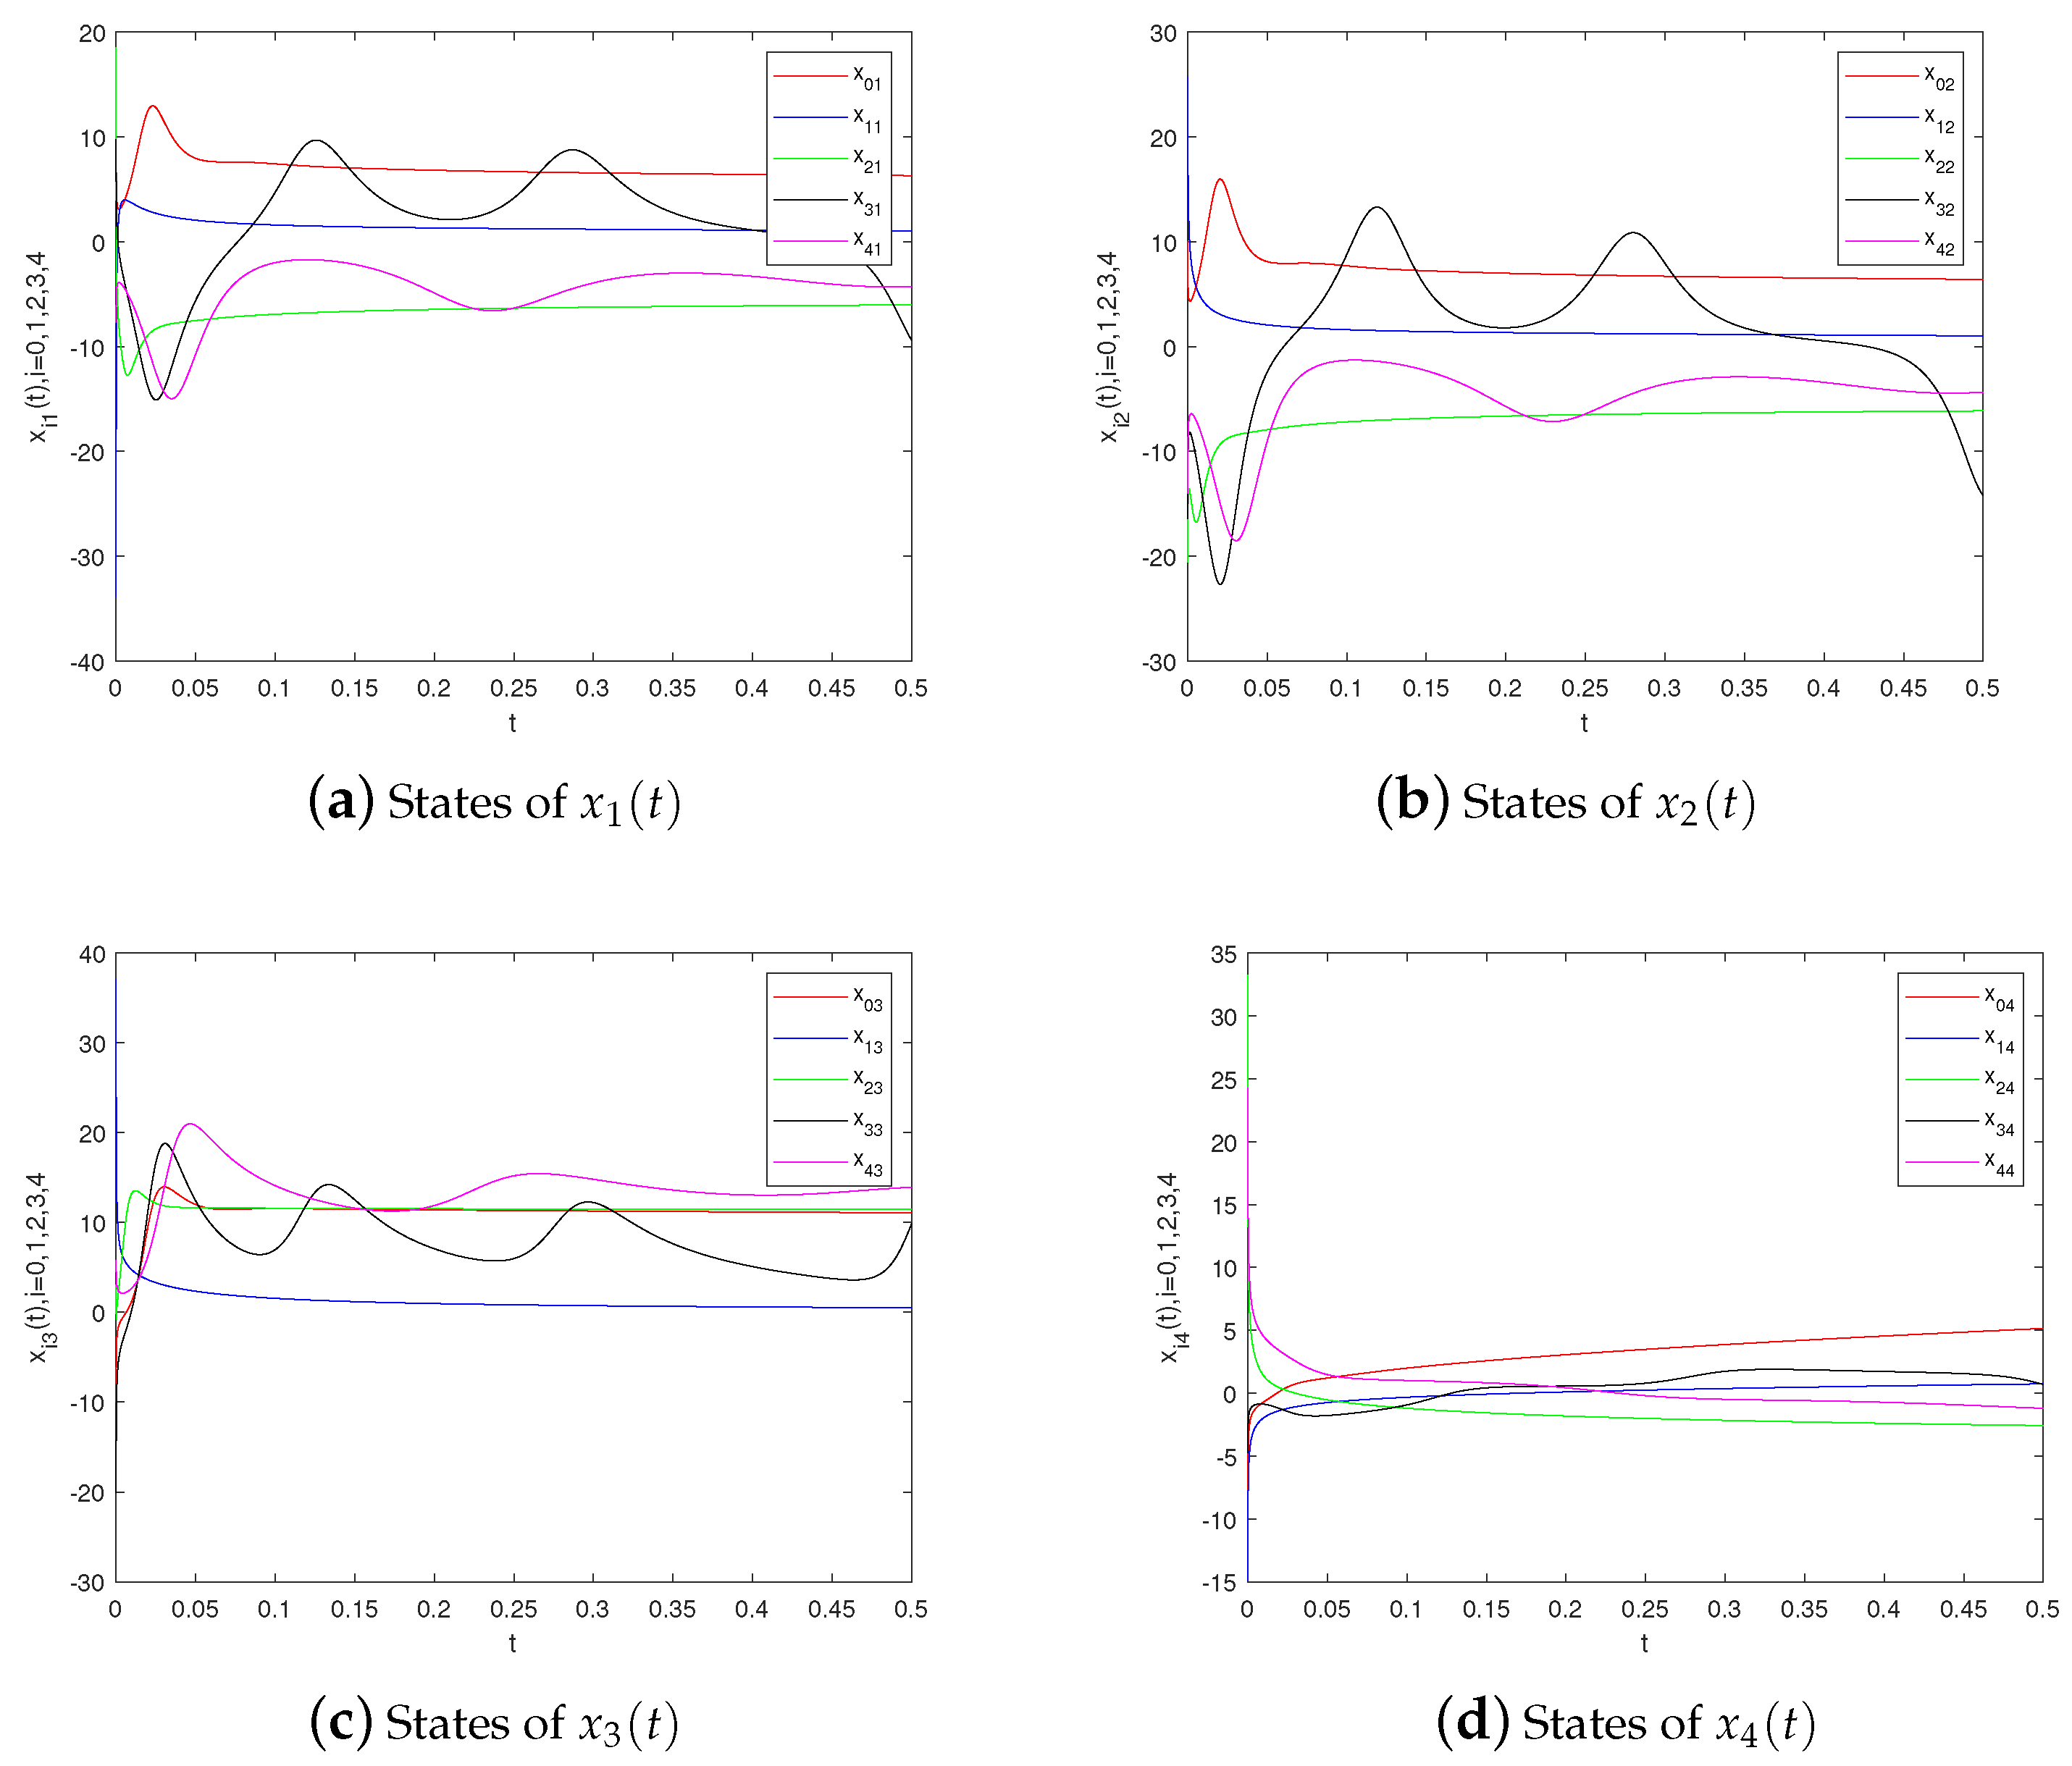
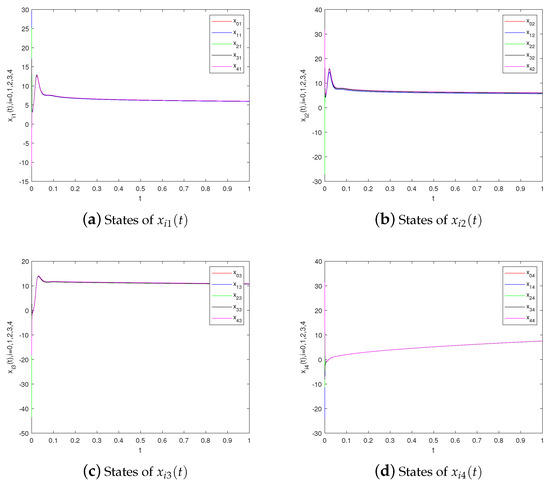
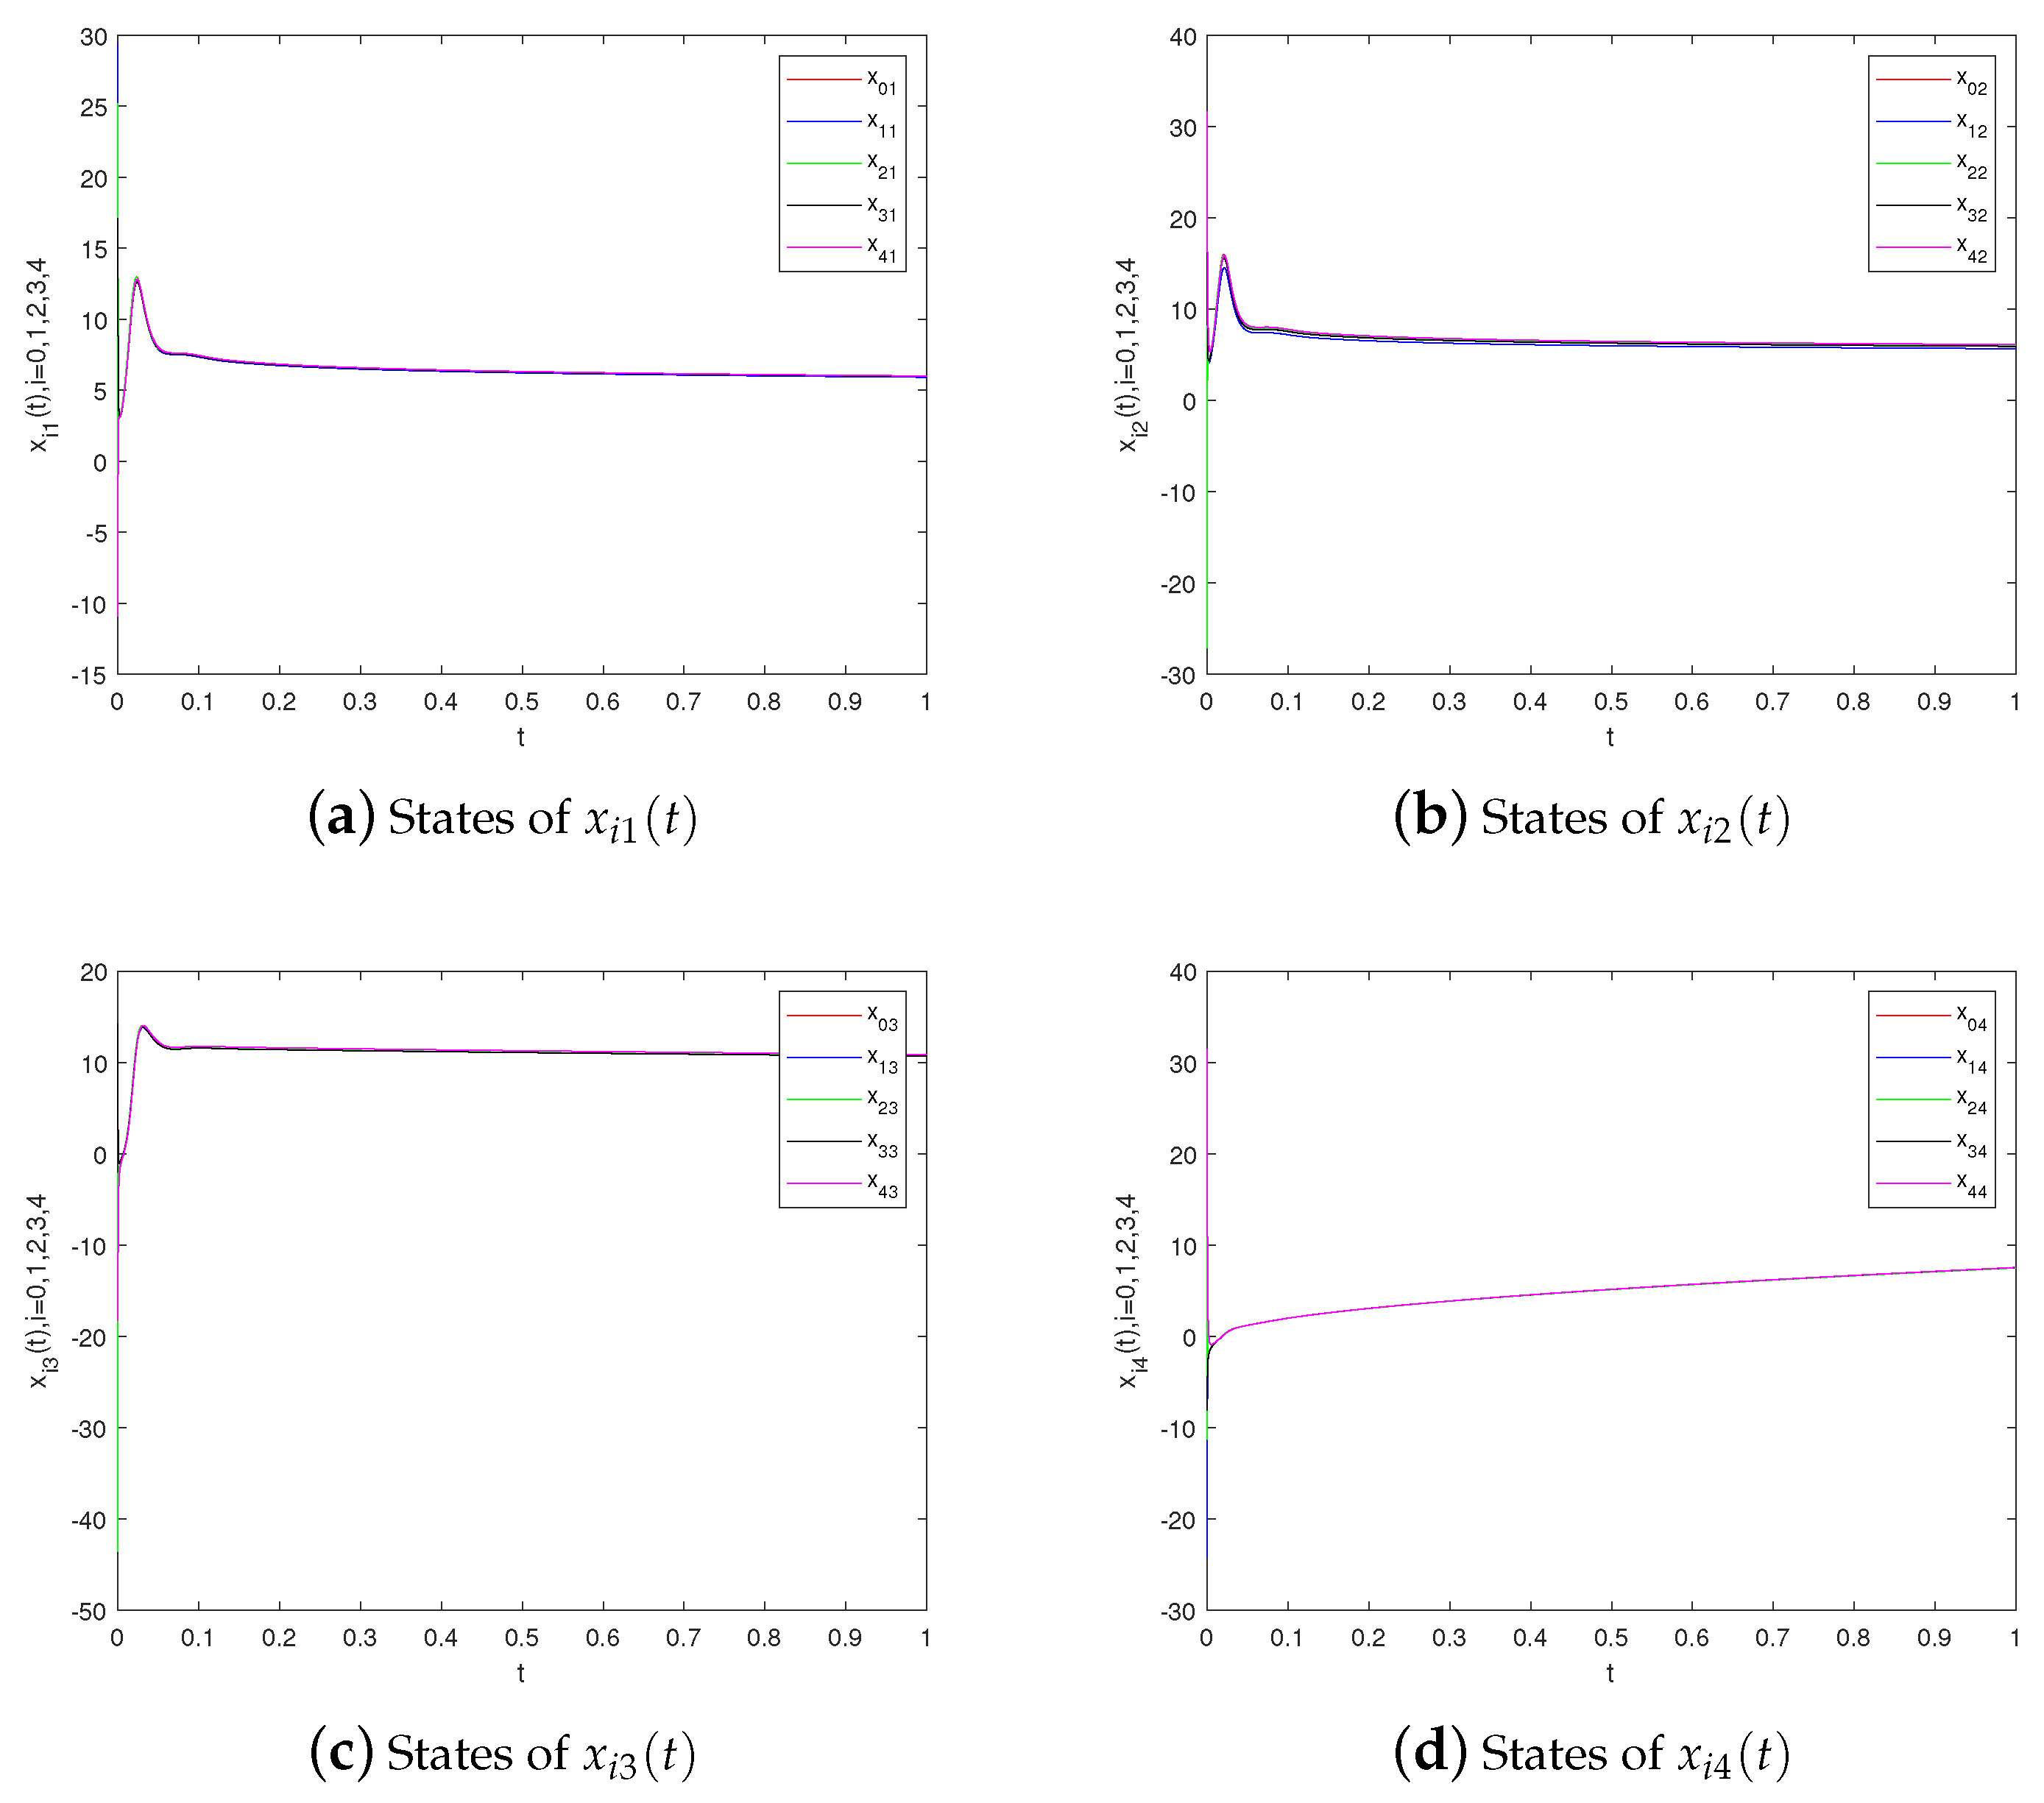
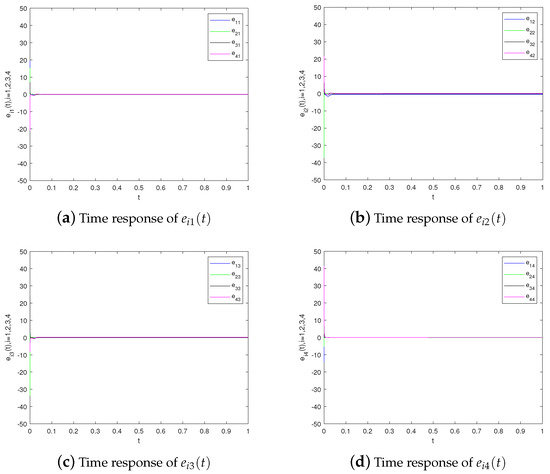
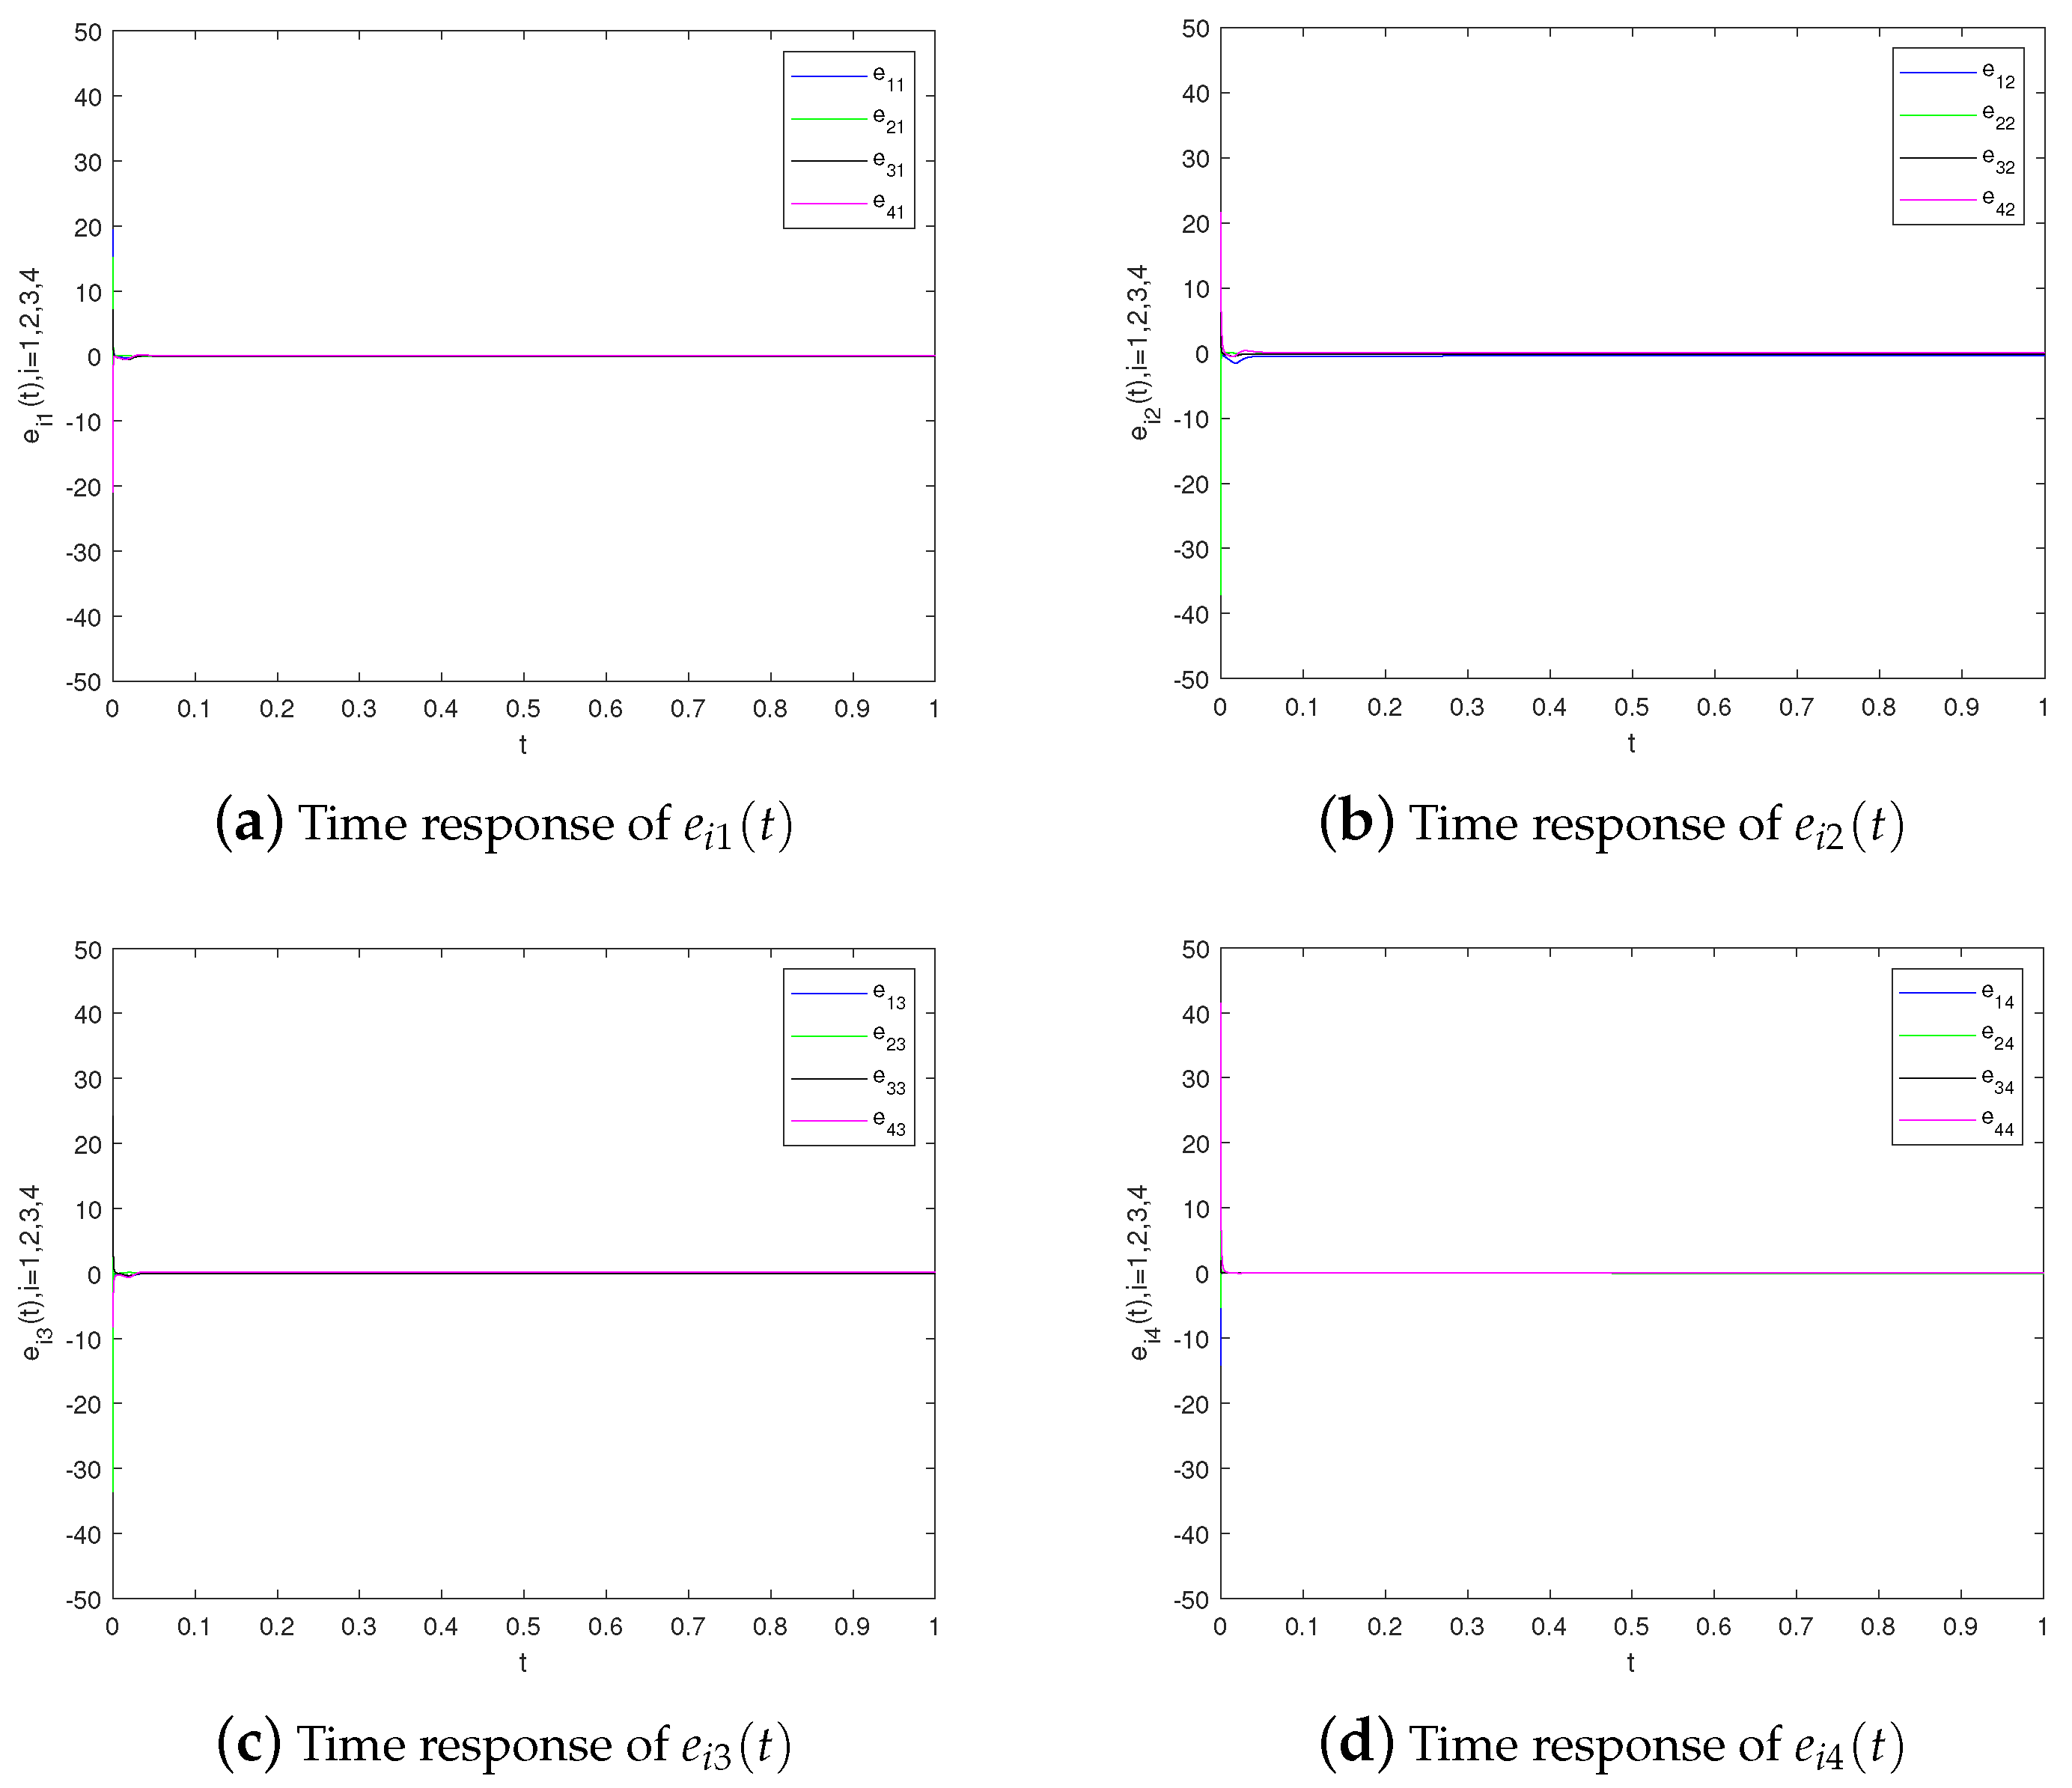
Under the above parameters, hyperchaos behaviors will occur of . The phase portraits of the leader are shown in Figure 1 with the initial values . Let be random between . Then, without control, the states of are shown in Figure 2. It is obvious that they are chaotic, stable, unstable, etc. Let , , , and . It is easy to see that, without control, the synchronization error is toward infinity (due to unstable). However, under control, the consensus can be achieved, and the states and errors are shown in Figure 3 and Figure 4, respectively.
Figure 1.
(a–d) Hyperchaos behaviors of leader .
Figure 2.
(a–d) States of without control.
Figure 3.
(a–d) Consensus behaviors of with control.
Figure 4.
(a–d) Consensus errors with control.
Remark 3.
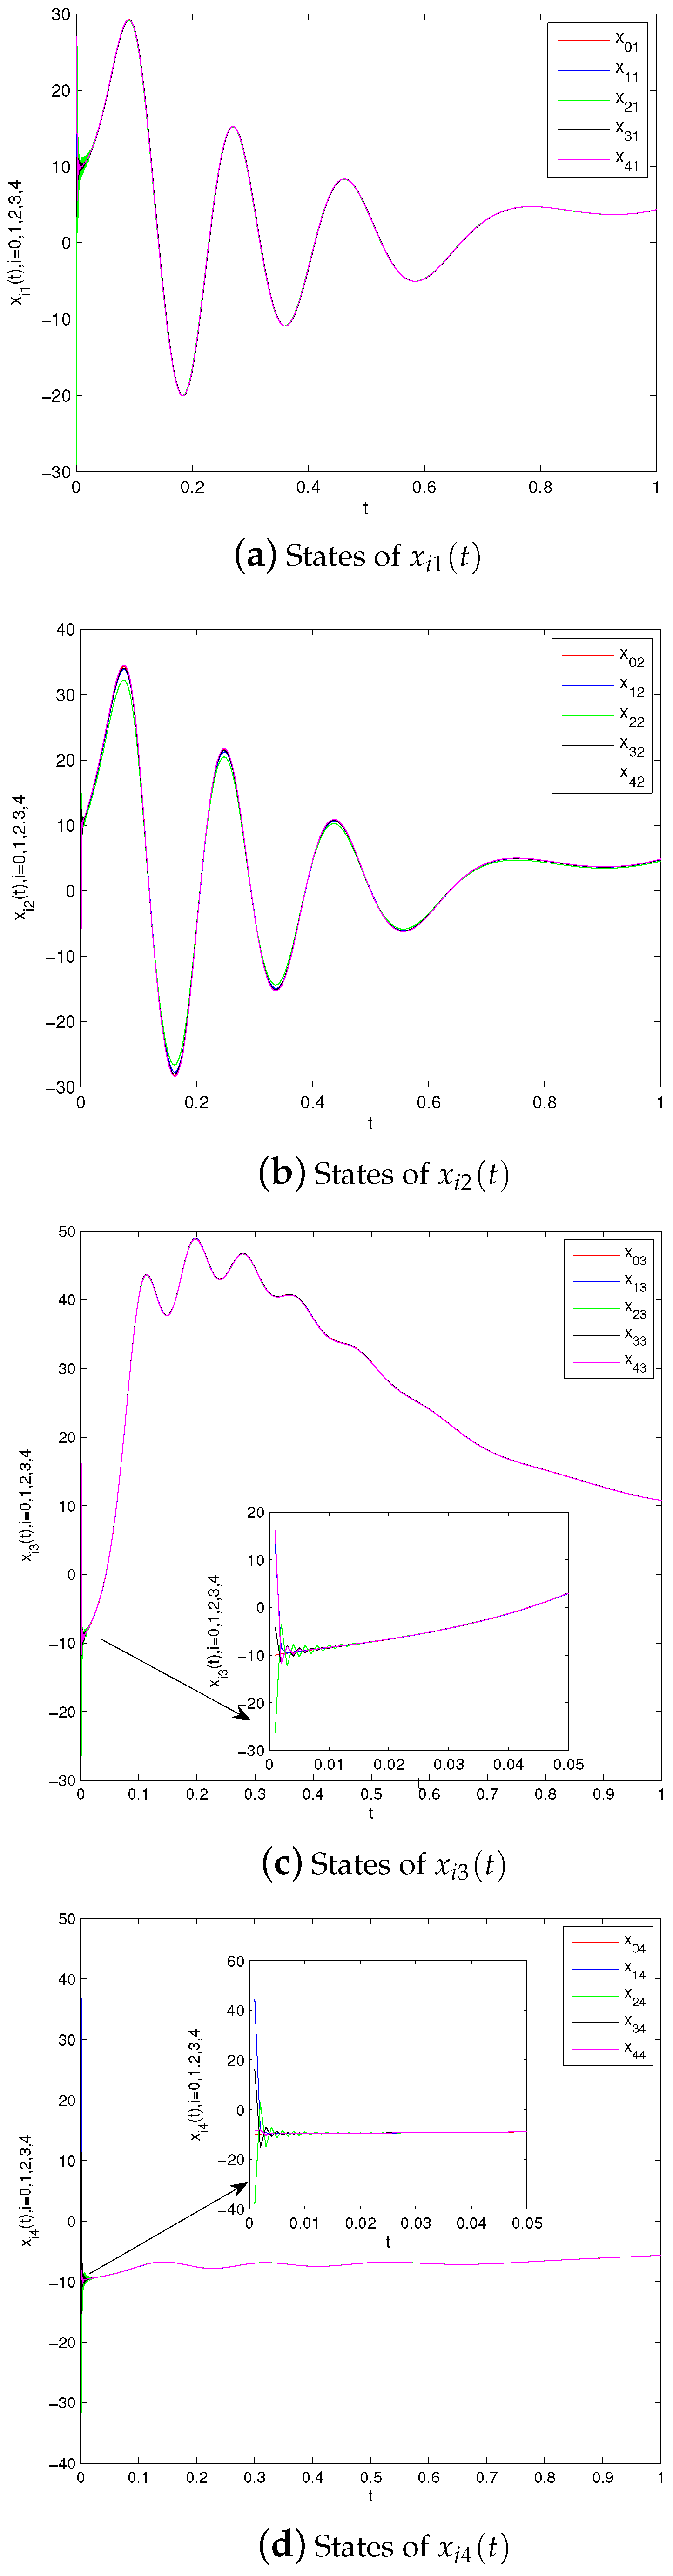
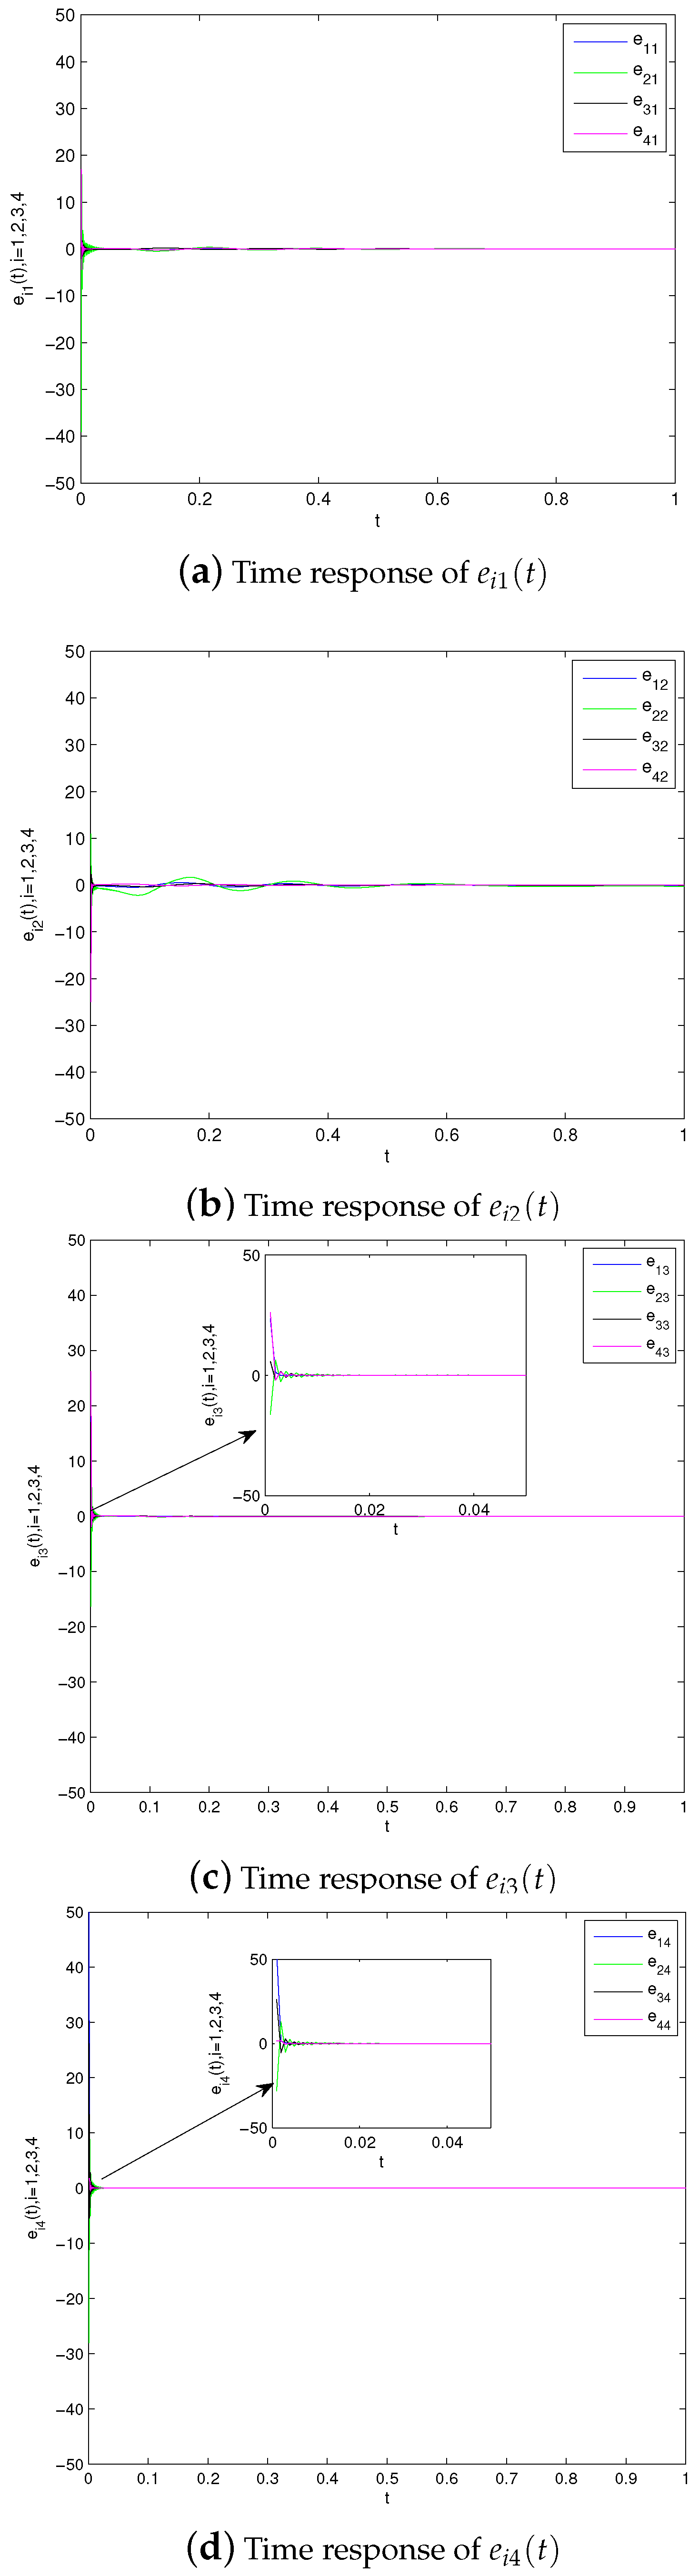
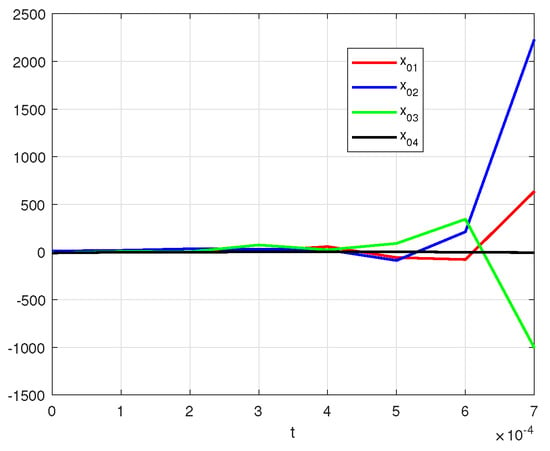
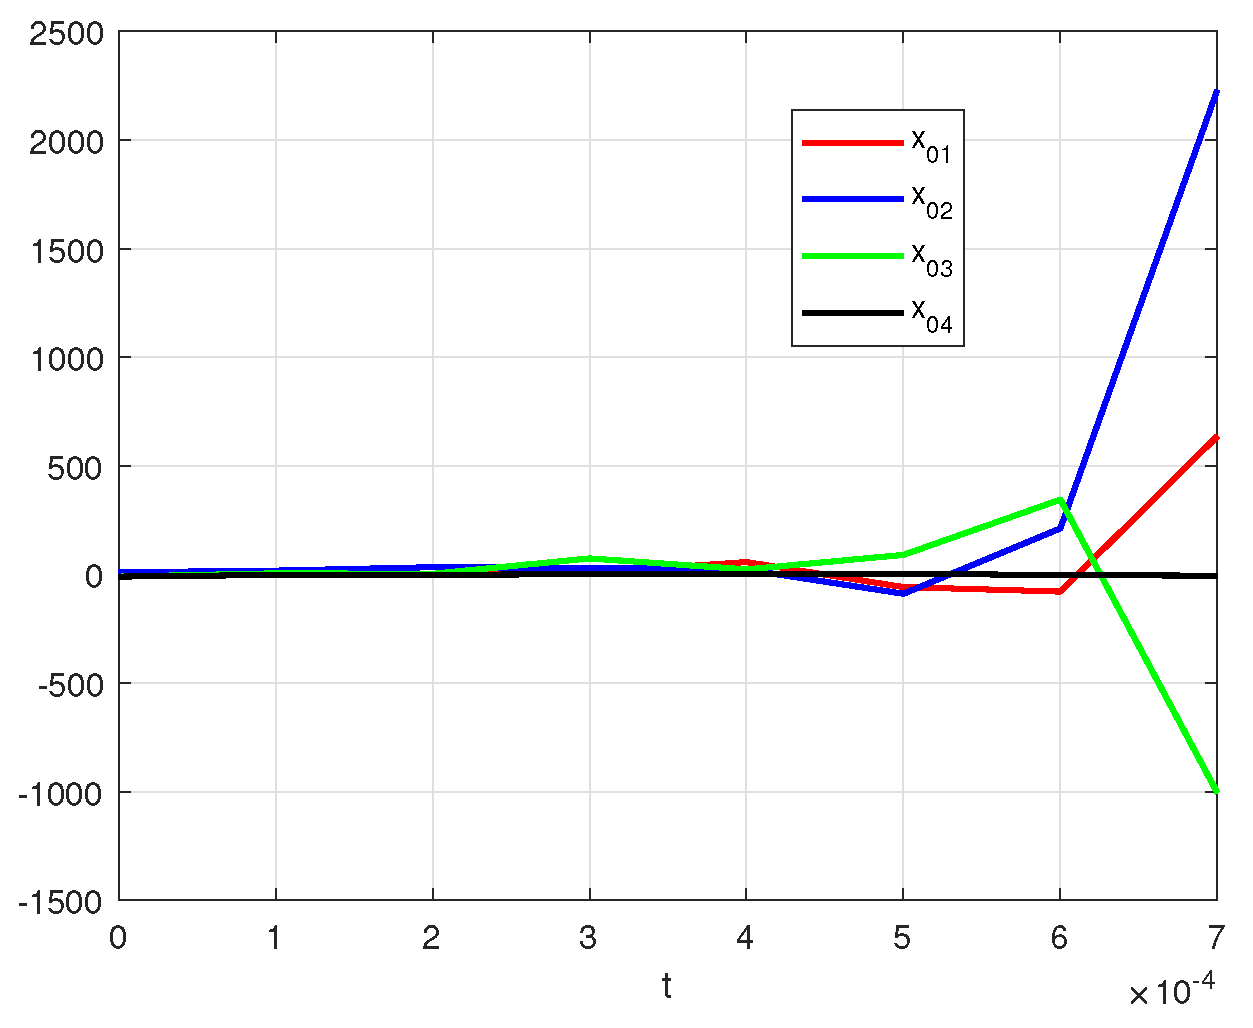
Noting that the order is a significant parameter in the analysis of the dynamics of the fractional-order systems, if the orders are too low, namely, close to zero, the systems usually diverge to infinity. For example, if we set , then, the states of the leader can be seen in the Figure 5, where the steps of the simulation are selected as . Furthermore, the numerical algorithms of the fractional-order differential equations are in the stage of development; when the order is low, it is difficult to achieve high accuracy. When we set , , , , , as one can see in Figure 6. It is easy to see that, without control, the consensus cannot be achieved. However, under control, the consensus can be achieved, as one can see in Figure 7 and Figure 8. Furthermore, the dynamical behaviors are different from the manuscript.
Figure 5.
States of leader when .
Figure 6.
(a–d) States of without control, , , , , .
Figure 7.
(a–d) Consensus behaviors of with control, , , , , .
Figure 8.
(a–d) Consensus errors with control, , , , , .
6. Conclusions
In this paper, an incommensurate heterogeneous fractional-order multi-agent system has been studied. As a main theory tool, the Vector Lyapunov Function method for incommensurate fractional-order systems has been discussed. Then, a leader (target) with unknown parameters and orders has been tracked under a discontinuous distributed control protocol. Different from some existing studies, the complete consensus can be achieved with the proposed control strategy instead of a bounded consensus. In general, this manuscript has constructed the theoretical analytical framework for the leader-following consensus of incommensurate fractional-order multi-agent systems. As we all know, there exist many constraints in the communications among agents, such as time delay, stochastic disturbances, bandwidth limitation, etc. In the future, we will extend the framework of this manuscript to fit a more practical networked environment.
Author Contributions
C.H.: writing—original draft preparation, funding acquisition. F.W.: writing—review and editing, visualization, funding acquisition. All authors have read and agreed to the published version of the manuscript.
Funding
This research is supported by the project funded by the High end Training Program for Professional Leaders of Vocational College Teachers in Jiangsu Province (Sugao Peihan [2022] No.11), Jiangsu Province Demonstration Virtual Simulation Training Base Cultivation Project (Sujiao Zhihan [2023] No.30), the Natural Science Foundation of Shandong Province (No: ZR2022QF075), the Project Supported by the Foundation of Key Laboratory of Advanced Process Control for Light Industry (Jiangnan University) Ministry of Education, P.R.China (No: APCLI2403).
Data Availability Statement
The authors confirm that the data supporting the findings of this study are available within the article.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Olfati-Saber, R.; Murray, R. Consensus problems in networks of agents with switching topology and time-delays. IEEE Trans. Autom. Control 2004, 49, 1520–1533. [Google Scholar] [CrossRef] [Scilit]
- Cao, Y.; Yu, W.; Ren, W.; Chen, G. An overview of recent progress in the study of distributed multi-agent coordination. IEEE Trans. Ind. Inform. 2012, 9, 427–438. [Google Scholar] [CrossRef] [Scilit]
- Oh, K.; Park, M.; Ahn, H. A survey of multi-agent formation control. Automatica 2015, 53, 424–440. [Google Scholar] [CrossRef] [Scilit]
- Qin, J.; Ma, Q.; Shi, Y.; Wang, L. Recent advances in consensus of multi-agent systems: A brief survey. IEEE Trans. Ind. Electron. 2016, 64, 4972–4983. [Google Scholar] [CrossRef] [Scilit]
- Yu, W.; Zheng, W.; Chen, G.; Ren, W.; Cao, J. Second-order consensus in multi-agent dynamical systems with sampled position data. Automatica 2011, 47, 1496–1503. [Google Scholar] [CrossRef] [Scilit]
- Cao, Y.; Li, Y.; Ren, W.; Chen, Y. Distributed coordination of networked fractional-order systems. IEEE Trans. Syst. Man Cybern. Part Cybern. 2009, 40, 362–370. [Google Scholar]
- Yu, Z.; Jiang, H.; Hu, C.; Yu, J. Necessary and sufficient conditions for consensus of fractional-order multiagent systems via sampled-data control. IEEE Trans. Cybern. 2017, 47, 1892–1901. [Google Scholar] [CrossRef] [Scilit]
- Su, H.; Ye, Y.; Chen, X.; He, H. Necessary and sufficient conditions for consensus in fractional-order multiagent systems via sampled data over directed graph. IEEE Trans. Syst. Man Cybern. Syst. 2021, 51, 2501–2511. [Google Scholar] [CrossRef] [Scilit]
- Gong, P.; Lan, W.; Han, Q. Robust adaptive fault-tolerant consensus control for uncertain nonlinear fractional-order multi-agent systems with directed topologies. Automatica 2020, 117, 109011. [Google Scholar] [CrossRef] [Scilit]
- Gong, P.; Wang, K. Output feedback consensus control for fractional-order nonlinear multi-agent systems with directed topologies. J. Frankl. Inst. 2020, 357, 1473–1493. [Google Scholar] [CrossRef] [Scilit]
- Du, H.; Wen, G.; Wu, D.; Cheng, Y.; Lu¨, J. Distributed fixed-time consensus for nonlinear heterogeneous multi-agent systems. Automatica 2020, 113, 108797. [Google Scholar] [CrossRef] [Scilit]
- Li, X.; Yu, Z.; Li, Z.; Wu, N. Group consensus via pinning control for a class of heterogeneous multi-agent systems with input constraints. Inf. Sci. 2021, 542, 247–262. [Google Scholar] [CrossRef] [Scilit]
- Zhao, Y.; Xian, C.; Wen, G.; Huang, P.; Ren, W. Design of distributed event-triggered average tracking algorithms for homogeneous and heterogeneous multi-agent systems. IEEE Trans. Autom. Control 2021, 67, 1269–1284. [Google Scholar] [CrossRef] [Scilit]
- Han, T.; Zheng, W. Bipartite output consensus for heterogeneous multi-agent systems via output regulation approach. IEEE Trans. Circuits Syst. II Express Briefs 2020, 68, 281–285. [Google Scholar] [CrossRef] [Scilit]
- Gong, P. Distributed tracking of heterogeneous nonlinear fractional-order multi-agent systems with an unknown leader. J. Frankl. Inst. 2017, 354, 2226–2244. [Google Scholar] [CrossRef] [Scilit]
- Wang, F.; Yang, Y. Quasi-synchronization for fractional-order delayed dynamical networks with heterogeneous nodes. Appl. Math. Comput. 2018, 339, 1–14. [Google Scholar] [CrossRef] [Scilit]
- Gao, Z.; Zhang, H.; Zhang, J.; Sun, S. Semi-global leader-following output consensus for heterogeneous fractional-order multi-agent systems with input saturation via observer-based protocol. Neurocomputing 2020, 402, 298–306. [Google Scholar] [CrossRef] [Scilit]
- Wang, F.; Zheng, Z.; Yang, Y. Quasi-synchronization of heterogenous fractional-order dynamical networks with time-varying delay via distributed impulsive control. Chaos, Solitons Fractals 2021, 142, 110465. [Google Scholar] [CrossRef] [Scilit]
- Fan, H.; Rao, Y.; Shi, K.; Wen, H. Time-varying function matrix projection synchronization of Caputo fractional-order uncertain memristive neural networks with multiple delays via mixed open loop feedback control and impulsive control. Fractal Fract. 2024, 8, 301. [Google Scholar] [CrossRef] [Scilit]
- Fan, H.; Chen, X.; Shi, K.; Liang, Y.; Wang, Y.; Wen, H. Mittag-Leffler synchronization in finite time for uncertain fractional-order multi-delayed memristive neural networks with time-varying perturbations via information feedback. Fractal Fract. 2024, 8, 422. [Google Scholar] [CrossRef] [Scilit]
- Gong, P.; Han, Q.; Lan, W. Finite-time consensus tracking for incommensurate fractional-order nonlinear multiagent systems with directed switching topologies. IEEE Trans. Cybern. 2020, 52, 65–76. [Google Scholar] [CrossRef] [PubMed]
- Gong, P.; Han, Q. Practical fixed-time bipartite consensus of nonlinear incommensurate fractional-order multiagent systems in directed signed networks. SIAM J. Control Optim. 2020, 58, 3322–3341. [Google Scholar] [CrossRef] [Scilit]
- Shahvali, M.; Naghibi-Sistani, M.; Modares, H. Distributed consensus control for a network of incommensurate fractional-order systems. IEEE Control Syst. Lett. 2019, 3, 481–486. [Google Scholar] [CrossRef] [Scilit]
- Kilbas, A.; Srivastava, H.; Trujillo, J. Theory and Applications of Fractional Differential Equations; Elsevier: New York, NY, USA, 2006. [Google Scholar]
- Xu, Q.; Zhuang, S.; Liu, S.; Xiao, J. Decentralized adaptive coupling synchronization of fractional-order complex-variable dynamical networks. Neurocomputing 2016, 186, 119–126. [Google Scholar] [CrossRef] [Scilit]
- Rami, M.; Tadeo, F. Controller synthesis for positive linear systems with bounded controls. IEEE Trans. Circuits Syst. II Express Briefs 2007, 54, 151–155. [Google Scholar] [CrossRef] [Scilit]
- Balachandran, K. An Introduction to Fractional Differential Equations; Springer: Singapore, 2023. [Google Scholar]
- Shen, J.; Lam, J. Stability and performance analysis for positive fractional-order systems with time-varying delays. IEEE Trans. Autom. Control 2016, 61, 2676–2681. [Google Scholar] [CrossRef] [Scilit]
- Lu, S.; Wang, X. Adaptive neural network output feedback control of incommensurate fractional-order PMSMs with input saturation via command filtering and state observer. Neural Comput. Appl. 2021, 33, 5631–5644. [Google Scholar] [CrossRef] [Scilit]
- Kaczorek, T. Selected Problems of Fractional Systems Theory; Springer: Berlin, Germany, 2011. [Google Scholar]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).