


Abstract
This paper conducts an in-depth study on the dynamic stability and complex vibration behavior of a 12-pole active magnetic bearing (AMB) system considering gravitational effects under a PD controller. Firstly, based on electromagnetic theory and Newton’s second law, a two-degree-of-freedom control equation of the system, including PD control terms and gravitational effects, is constructed. This equation involves not only parametric excitation, quadratic nonlinearity, and cubic nonlinearity but also a more pronounced coupling effect between the magnetic poles due to the presence of gravity. Secondly, using the multi-scale method, a four-dimensional averaged equation of the system in Cartesian and polar coordinates is derived. Finally, through numerical analysis, the system’s amplitude–frequency response, motion trajectory, the relationship between energy and amplitude, and global dynamic behaviors such as bifurcation and chaos are discussed in detail. The results show that the PD controller significantly affects the system’s spring hardening/softening characteristics, excitation, amplitude, energy, and stability. Specifically, increasing the proportional gain can quickly suppress the rotor’s motion, but it also increases the system’s instability. Adjusting the differential gain can transition the system from a chaotic state to a stable periodic motion.
MSC:
37N35; 34H05; 34H10; 34H20
1. Introduction
Active magnetic bearing (AMB) systems, as a key technology in modern high-precision rotating machinery, have advantages such as frictionless operation, no lubrication, and long service life, making them widely used in the aerospace, energy, and industrial automation fields [1]. With technological advancements, the performance requirements for AMB systems in high-precision and high-reliability applications continue to increase, making the study of system stability, energy consumption, and complex dynamic behavior particularly important. The nonlinear dynamic behavior of magnetic bearing systems is complex, and improper control can lead to system instability, affecting equipment performance and safety. In-depth research and the application of nonlinear control technology can effectively suppress vibrations, improve dynamic performance and stability, and promote the development of modern industry and technology. Therefore, the control study of nonlinear dynamic behavior in magnetic bearing systems has become a key focus area in academia.
In-depth research on the nonlinear behavior of magnetic bearing systems plays a crucial role in the development of magnetic bearing technology and significantly impacts modern industry and technological progress. Thus, the nonlinear dynamic behavior of magnetic bearing systems has become a key research focus in academia. Ji and Hansen [2] studied the nonlinear vibration behavior of a rotor in magnetic bearings, revealing the complex dynamic characteristics of the system under different excitation conditions. Amer et al. [3] explored the resonance behavior of a magnetic bearing rotor with time-varying stiffness, discovering complex nonlinear vibration phenomena under varying parameters. Inayat-Hussain [4] further revealed the complex behavior of the system by studying the geometric coupling effects of a nonlinear rotor in magnetic bearings. Eissa et al. [5] investigated the nonlinear behavior of a tuned rotor–magnetic bearing system with multi-parameter excitation, examining the stability and vibration modes of the system under specific parameters. Luo and Wang [6] analyzed the nonlinear vibration of a continuous rotor with lateral electromagnetic and bearing excitation, proposing the dynamic characteristics of the system under complex excitation. Saeed et al. [7] studied the nonlinear dynamics of a six-pole magnetic bearing system, highlighting the nonlinear vibration modes of the system under different control configurations. Zhang et al. [8] proposed a vibration suppression method based on a time-delay controller by studying a magnetic bearing system under multi-parameter excitation. Wu et al. [9] demonstrated that the effects of current saturation and a 16-pole leg structure on the nonlinear vibrations of the system are significant. Shourbagy et al. [10] explored the nonlinear electro-mechanical effects in a twelve-pole system controlled by a proportional–derivative controller.
With the widespread application of magnetic bearing systems in engineering, the study of their nonlinear control methods has gradually become a hotspot. Nonlinear control methods can effectively suppress system vibrations, improving system stability and dynamic performance. Ji [11] studied the stability and Hopf bifurcation behavior of a magnetic bearing system with time delay, providing a theoretical basis for the nonlinear control of the system. Kamel [12] studied the nonlinear behavior of an eight-pole rotor magnetic levitation system under multi parameter excitation. Inoue et al. [13] explored the impact of integral feedback on the nonlinear vibrations of a rigid rotating shaft in vertical-axis PID control, proposing a control strategy based on nonlinear vibration analysis. Sung et al. [14] controlled a six-degree-of-freedom active magnetic levitation bearing system using a robust fuzzy controller. Zhang et al. [15] proposed a new nonlinear time-varying stiffness control method by studying the control performance, stability conditions, and bifurcation behavior of a twelve-pole magnetic bearing system. Wu et al. [16] explored the dynamic analysis and vibration control of a magnetic bearing system under base motion, proposing a global bifurcation and chaos control method based on PD control. Xu et al. [17] proposed a dynamic model and scheme for controlling a rotor system with large eccentricity. Chang et al. [18] conducted a nonlinear dynamic analysis of a rotor system equipped with HSFD under secondary damping. Wang et al. [19] studied the control of magnetic bearing systems under conditions of positive and negative stiffness.
PD control, as a classical control method, has been widely used in the vibration control of magnetic bearing systems. By combining proportional and differential controllers, it effectively suppresses system vibrations and improves dynamic performance. Yeh et al. [20] studied the sliding mode control of a magnetic bearing system, proposing a sliding mode control strategy based on PD control, significantly enhancing system stability. Kaya [21] designed a PI-PD controller for unstable and integral process control, verifying its effectiveness in magnetic bearing systems. Jawaid [22] proposed a stability control strategy based on PD control by studying the geometric coupling effects of nonlinear rotors in magnetic bearings. Wu and Zhang [23] studied the nonlinear dynamics of a rotor–magnetic bearing system with time-varying stiffness, proposing a global bifurcation and chaos control method based on PD control. Ghazavi and Sun [24] proposed a nonlinear vibration suppression method based on PD control by studying the impact of time-varying stiffness on bifurcation delay in magnetic bearing systems. Saeed et al. [25] further verified the effectiveness of PD control in suppressing vibrations and improving stability in magnetic bearing systems. Ma et al. [26] studied the stability and multi-pulse jump chaos vibration of a 16-pole leg magnetic bearing system, proposing a nonlinear vibration suppression method based on PD control. Kandil et al. [27] proposed a global stability control strategy based on PD control by studying the nonlinear dynamics of a 16-pole rotor magnetic bearing system with constant stiffness coefficients. Saeed et al. [28] proposed a new system optimization method based on PD control by studying the nonlinear dynamics and motion bifurcation of a six-pole magnetic bearing system. Xu et al. [29] proposed an adaptive backstepping control method based on PD control by studying a slice rotor magnetic bearing. Wei et al. [30] proposed a nonlinear vibration suppression method based on PD control by exploring the dynamic analysis and vibration control of a magnetic bearing system under base motion. Zhou et al. [31] further verified the effectiveness of PD control in improving system stability and suppressing vibrations by studying the stability control of a magnetic suspension turbopump system. Kandil et al. [32] proposed a new algorithm based on a PD controller system by studying the impact of configuration angles on the oscillating rotor of an eight-pole active magnetic levitation bearing. In summary, research on PD-controlled magnetic bearing (AMB) systems mainly focuses on the effects of stiffness transformation, the number of magnetic poles, or the angles between the magnetic poles on the performance of the PD controller, with more attention given to six-pole and eight-pole active magnetic bearing systems.
The study in [33] explores the dynamic characteristics of a 12-pole active magnetic bearing (AMB) system incorporating a PD controller. By employing averaged equations in polar coordinates, stability charts and bifurcation diagrams of the system are generated, and the impact of the proportional gain and derivative gain on the nonlinear vibrations of the system is analyzed. This paper investigates the vibration characteristics of a 12-pole AMB system considering gravitational effects. Focusing on two controller parameters, the proportional coefficient and the differential gain , rotor trajectory diagrams, diagrams of the energy ratio versus the amplitude, and magnitude-frequency response curves are plotted using averaged equations in polar coordinates. Additionally, phase diagrams and bifurcation diagrams are generated using averaged equations in Cartesian coordinates. A comprehensive analysis is then conducted to evaluate the influence of these two control parameters on the vibration characteristics of the bearing system.
The structure of this paper is as follows: the second part establishes the mechanical model of a 12-pole rotor–AMB system considering gravity; the third part conducts a multi-scale analysis of the established mathematical model; the fourth part studies the impact of different PD control parameters on the system’s dynamic behavior through numerical simulation; finally, the main conclusions of this paper are presented. The research results indicate that by adjusting various parameters of the PD controller, the stability and control efficiency of the 12-pole rotor–AMB system can be significantly improved, effectively suppressing vibrations and achieving smooth periodic motion.
2. Mechanical Modeling and Control Differential Equations of Motion
In a 12-pole active magnetic bearing system, a pair of symmetrical drive electromagnets in differential mode are used to obtain a pair of magnetic forces in opposite directions, and according to the electromagnetic field theory, the magnetic force generated between a pair of magnetic poles [9] is:
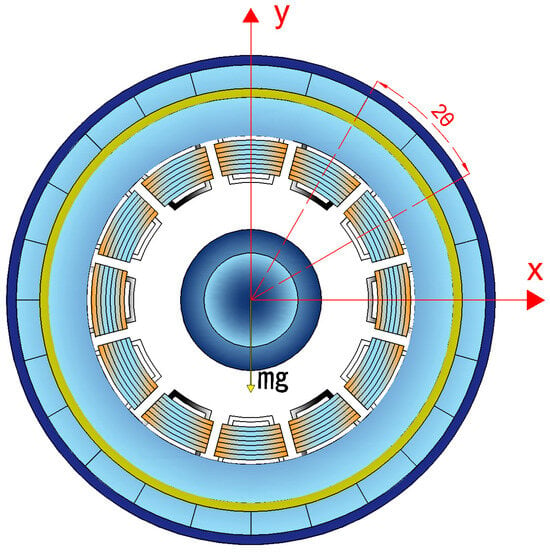
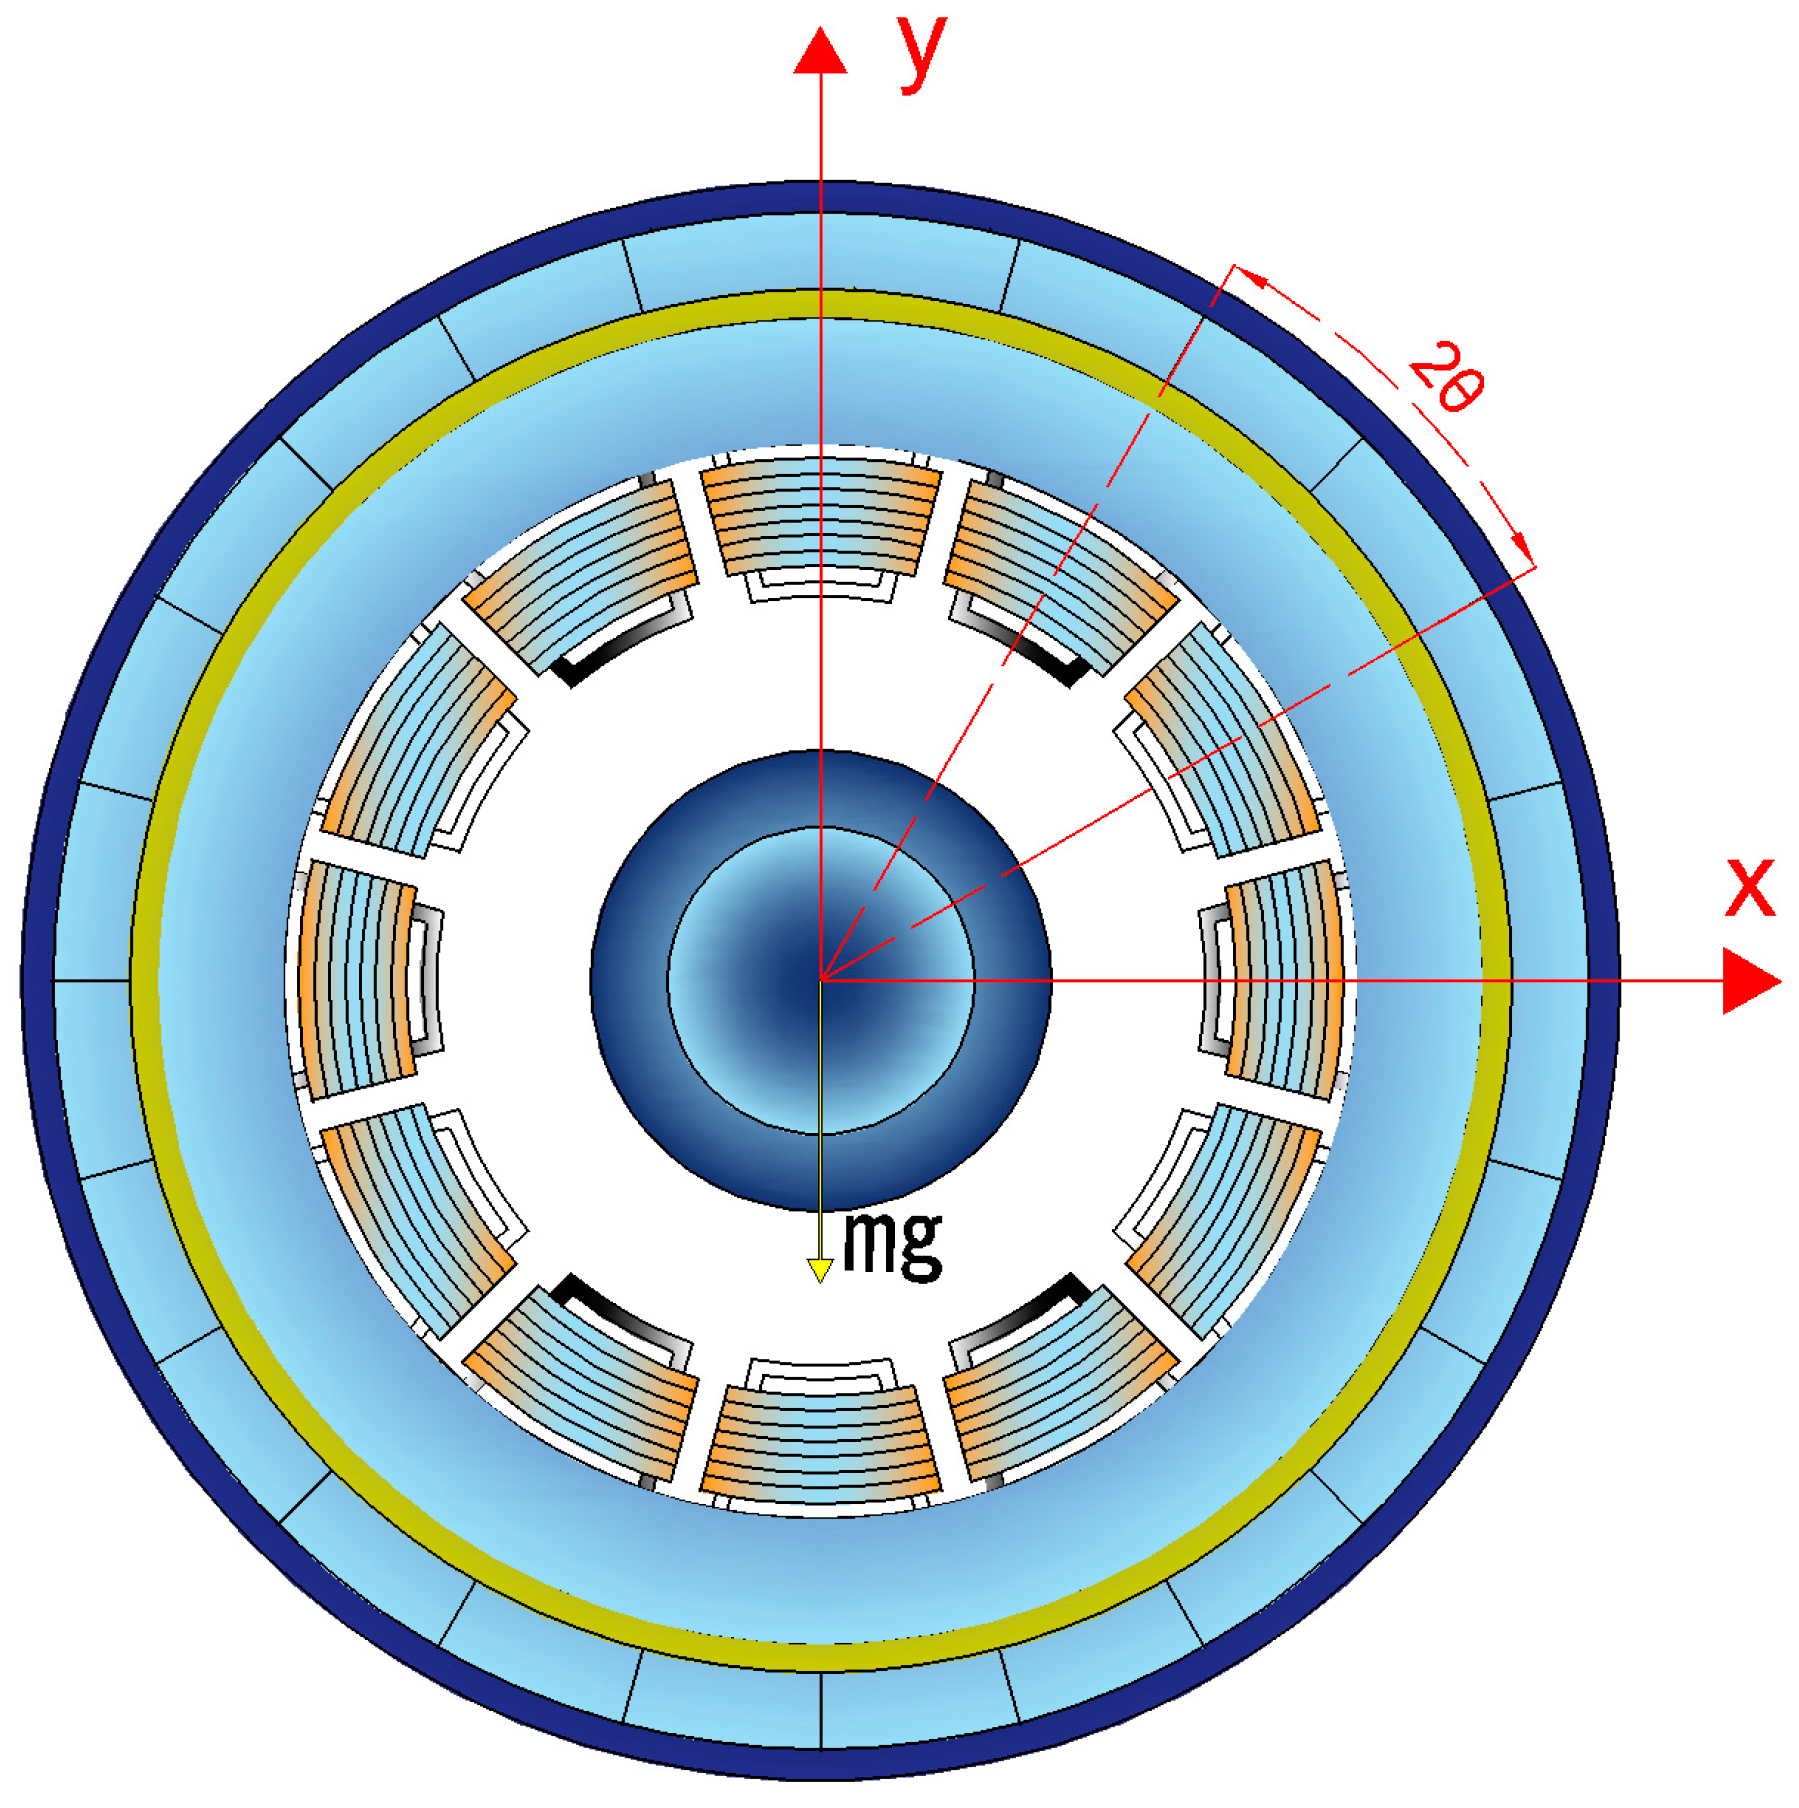
Figure 1 illustrates the schematic diagram of a 12-pole active magnetic bearing system. The bearing achieves rotor levitation and position control through radial magnetic levitation bearings and electromagnetic coils. When the rotor is centered, the gap between it and the bearing is fixed at a specific value. The system uses sensors to monitor the rotor position in real time. Upon detecting any deviation, the controller quickly responds, converting the signal into a control signal, which is then amplified to adjust the rotor’s position, ensuring the system’s stability and high precision. In a system consisting of 12-pole magnetic bearings, each pole typically includes a pair of opposing electromagnetic coils. According to Equation (1), the electromagnetic force generated by each set of coils can be expressed as:
where , , , , , . The constant represents the permeability of a vacuum, and it is used to describe the propagation of magnetic field lines in a vacuum. represents the cross-sectional area of the electromagnetic core, which influences the magnetic field strength generated by the electromagnet. is the number of turns of the electromagnetic coil, which is proportional to the magnetic field strength. is the displacement distance of the bearing rotor during motion, which occurs in a direction. is half of the angle between the two opposing magnetic poles. is the initial bias current applied to the electromagnetic coil, while is the control current applied in the direction, adjusted according to the feedback from the PD controller. This feedback adjustment process ensures the stable operation of the rotor, reducing or eliminating vibrations caused by displacement or other factors.
Figure 1.
Model of a 12-pole active magnetic bearing (AMB).
In a system consisting of a 12-pole active magnetic bearing system, each pole typically consists of a pair of opposing electromagnetic coils. Assuming the rotor to be a rigid body, considering the self-weight of the rotor, and neglecting eddy current losses, fringe flux, and saturation of the core material, the equations of motion of the rotor, applying Newton’s theorem, can be expressed as:
where represents the horizontal displacement of the rotor, represents the electromagnetic force in the horizontal direction, represents the vertical displacement of the rotor, represents the electromagnetic force in the vertical direction, represents the eccentricity of the rotor, and represents the rotor’s angular velocity.
This paper uses a proportional–derivative (PD) controller to achieve the control effects on the magnetic bearing. The PD controller sets a specific proportional gain and derivative gain , making the current proportional to the rotor’s displacement and velocity. This control method ensures an accurate response of the system to the rotor’s displacement and velocity [22]. The specific relationship can be expressed as:
To control the stability and motion of the magnetic bearing system using a PD controller, the PD controller is approximated as a spring with a damping element. The proportional gain coefficient is set to vary periodically over time.
In the 12-pole active magnetic bearing system, when we consider the rotor’s displacement as motion in the plane, we can transform the displacement distances in the 6 directions into representations in the plane coordinate system through coordinate transformation. This method intuitively reflects the rotor’s positional changes in two-dimensional space, as shown below:
In the 12-pole active magnetic bearing system, we need to decompose the electromagnetic force generated by each set of electromagnets into two components, the horizontal component and the vertical component . The expressions for and can be derived from Equation (2) as follows:
Combining with Equation (5), we can derive the expressions describing the relationship between and with the coordinates and :
Substituting Equation (7) into Equations (8) and (9), we obtain:
where .
To obtain the modified expression for the electromagnetic force, we can perform a Taylor expansion of Equations (12) and (13) at and , respectively, ignoring the third-order and higher-order terms. The resulting expression is as follows:
where the values in Equations (8) and (9) are:
where .
Substituting Equation (3) into Equations (12) and (13), the motion equation of the 12-pole active magnetic bearing system can be obtained as follows:
In nonlinear dynamics, nondimensionalization simplifies calculations. It helps in comparing different physical quantities without worrying about units and turns complex problems into simpler ones, making analysis easier.
Letting and introducing the dimensionless variables leads to the following:
The processed dimensionless motion equations are:
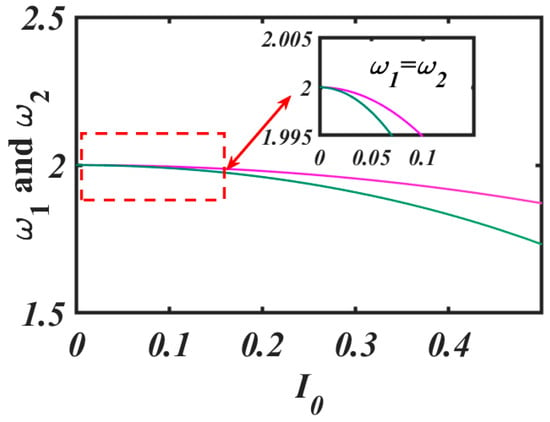
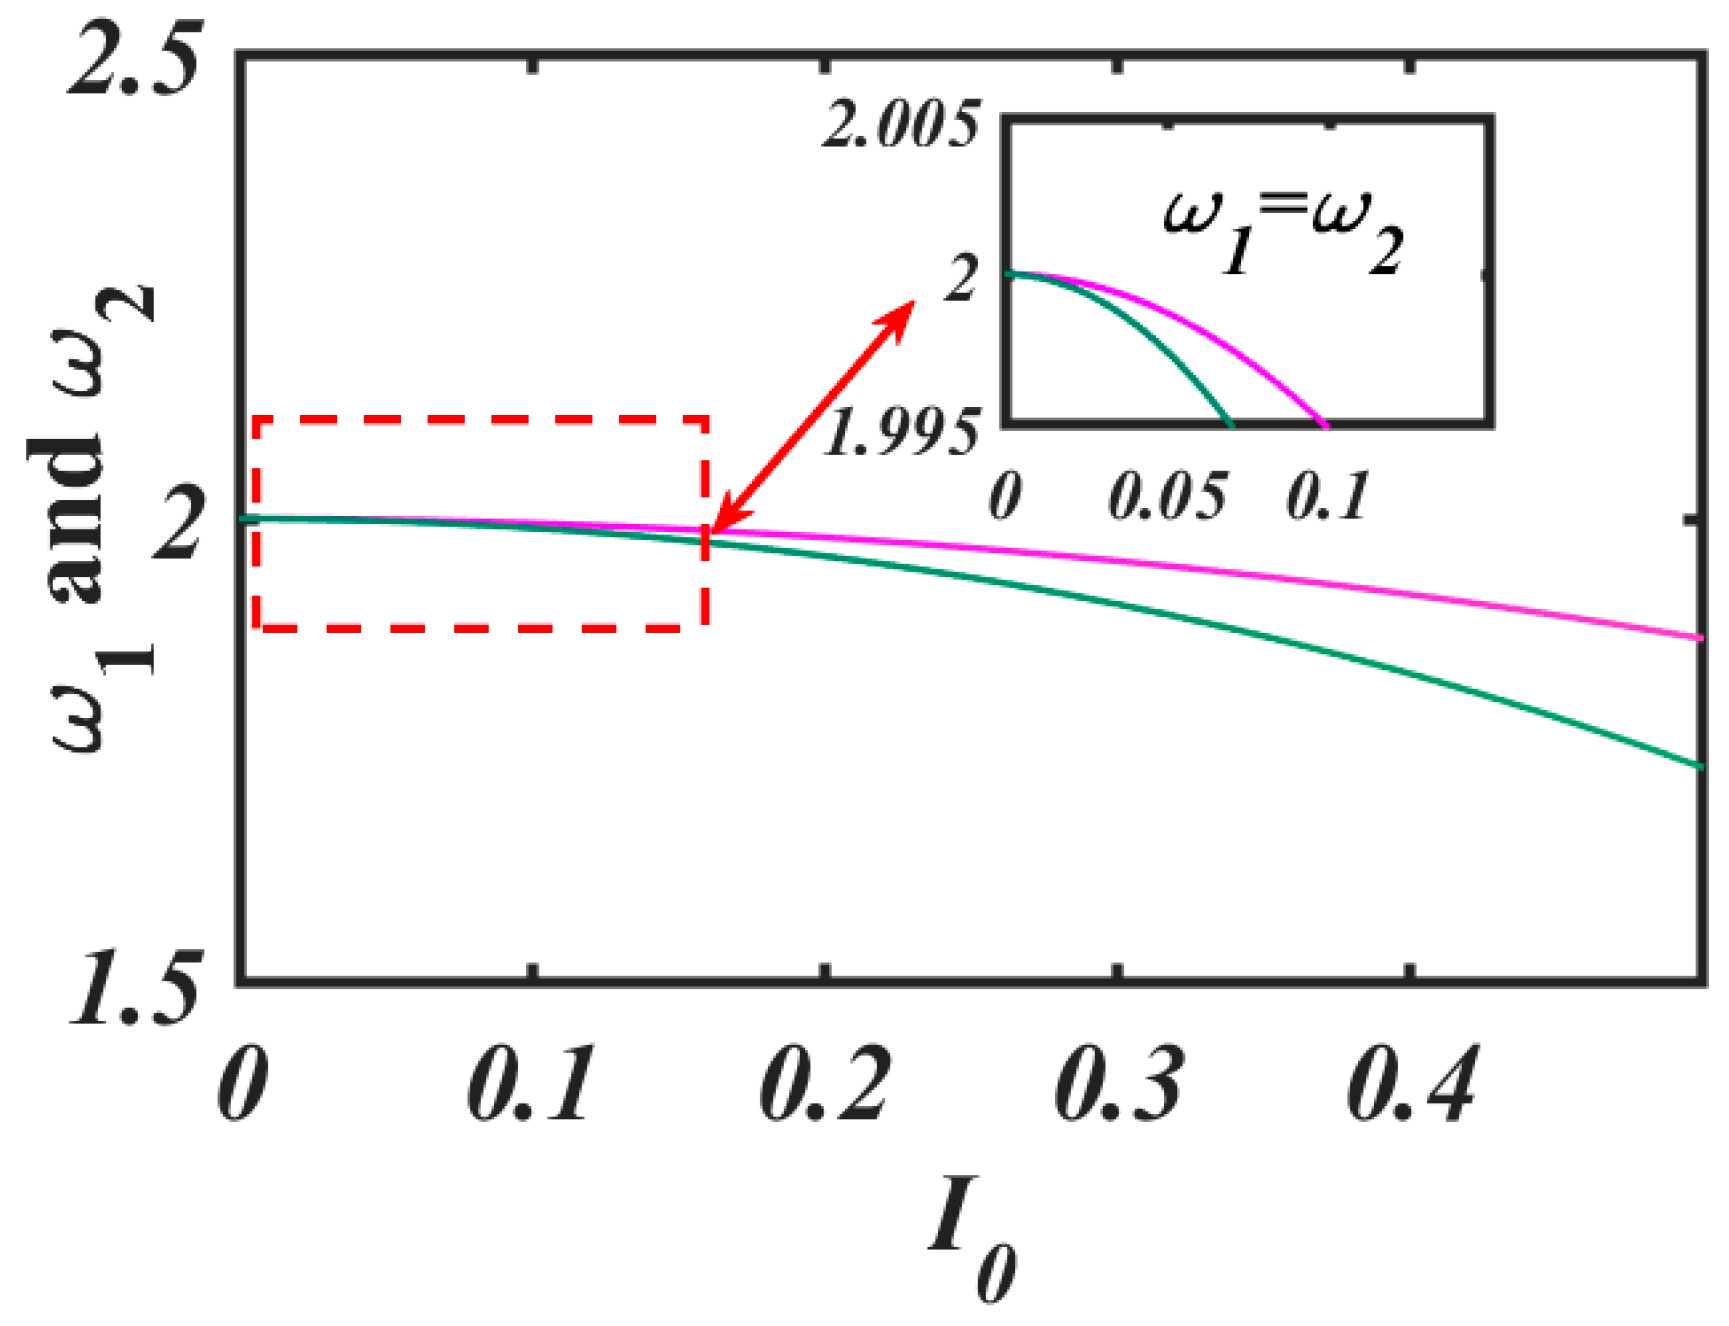
Based on the expressions for the natural frequencies and , the relationship between the first-order-mode natural frequency and second-order-mode natural frequency with the static feedback current can be obtained as follows, where the red line represents and the blue line represents .
As shown in Figure 2, when the static feedback current is in the range of , the natural frequencies of the two modes are approximately equal. Therefore, the 12-pole active magnetic bearing system studied in this paper exhibits 1:1 internal resonance.
Figure 2.
The functional relationship between the natural frequencies of the first-order mode and second-order mode with the feedback current.
3. Multiscale Perturbation Analysis
Nonlinear dynamic systems often exhibit complex, multi-scale behavior that is difficult to fully understand and describe on a single scale. Multi-scale analysis is an effective approximation method that helps to better analyze the dynamic characteristics of such systems. In this paper, we apply the multiple time scale perturbation analysis method [34] to the proposed Equations (20) and (21) and perform the following scale transformation.
To deeply analyze the nonlinear dynamic characteristics of the 12-pole active magnetic bearing system, we can adopt a scaling method for transformation. By introducing a small perturbation parameter , we can simplify the analysis process and thus derive the system’s averaged equations:
Substituting Equation (22) into Equations (20) and (21), we obtain the scaled dynamic control equations for the 12-pole active magnetic bearing system:
Using the multiple time scale perturbation method, we obtain the first-order approximate solution of Equations (23) and (24) as follows:
Introducing the fast time scale and the slow time scale , which describe the vibration behavior and long-term behavior, respectively, we can obtain the differential operator:
where .
Under the given conditions, since the mass, stiffness, and damping parameters remain symmetrical, we can reasonably assume a 1:1 internal resonance between the vibrations in the and directions based on the relationship in Equation (19). Such internal resonance indicates that the vibrations in both directions have the same frequency, which simplifies the analysis of the system’s dynamic behavior. The relationship is derived as:
Here, the tuning parameters and are introduced to quantify the proximity between the first-order-mode natural frequency and the second-order-mode natural frequency.
When we substitute Equations (27)–(29) into Equations (23) and (24) and compare the coefficients of the same powers of the variable on both sides of the equation, we obtain a series of relationships:
order:
order:
The approximate solution of Equations (30) and (31) are in the following form:
where represents the imaginary unit, and represent the amplitudes in the -axis and -axis directions, respectively, and and represent the conjugate forms of and , respectively. Substituting Equations (34) and (35) into Equations (32) and (33), we obtain:
where:
The right-hand sides of Equations (36) and (37) are composed of secular terms and , conjugate term , and non-secular term , respectively. In order to ensure the physical rationality and mathematical applicability of the solution, and to prevent infinite amplitude growth and energy accumulation caused by resonance in the system, it is necessary to set the secular term coefficients and to zero, which yields the following equations:
Transforming Equations (36) and (37) into polar coordinates gives the following:
Substituting Equations (38) and (39) into Equations (36) and (37), we obtain the four-dimensional averaged equations in the polar coordinate system:
Based on Equations (36) and (37), representing A and B in Cartesian form, the following transformation is made:
Substituting Equation (45) into Equations (38) and (39), the four-dimensional averaged equations in Cartesian form are obtained as follows:
In the following research, we will further study the nonlinear dynamic characteristics of the 12-pole active magnetic bearing PD controller by using the averaged equations in two different coordinate systems from Equations (41)–(44) and (46)–(49).
4. Numerical Simulation
4.1. Inherent Characteristic Analysis under PD Control
When , , , and in Equations (41)–(44), the system exhibits periodic solutions. Therefore, by combining Equations (41)–(44), we obtain the magnitude-frequency response functions of the 12-pole active magnetic bearing system in the horizontal and vertical directions:
In the design of the 12-pole active magnetic bearing system, to better approximate real operating conditions, it is necessary to fully consider the magnetic coupling effect between adjacent poles in addition to the influence of gravity. This magnetic coupling phenomenon directly affects the system’s dynamic behavior and stability in actual operation and cannot be ignored. Therefore, a weak coupling effect between the amplitudes in the and directions is specifically set.
Substituting into Equation (50) gives the following:
Substituting into Equation (51) gives the following:
where , .
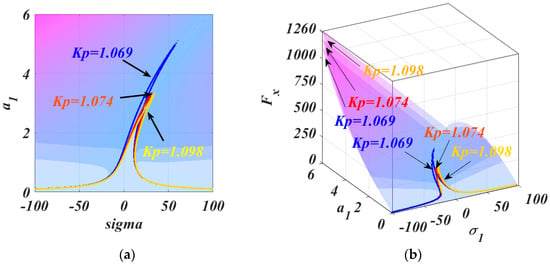
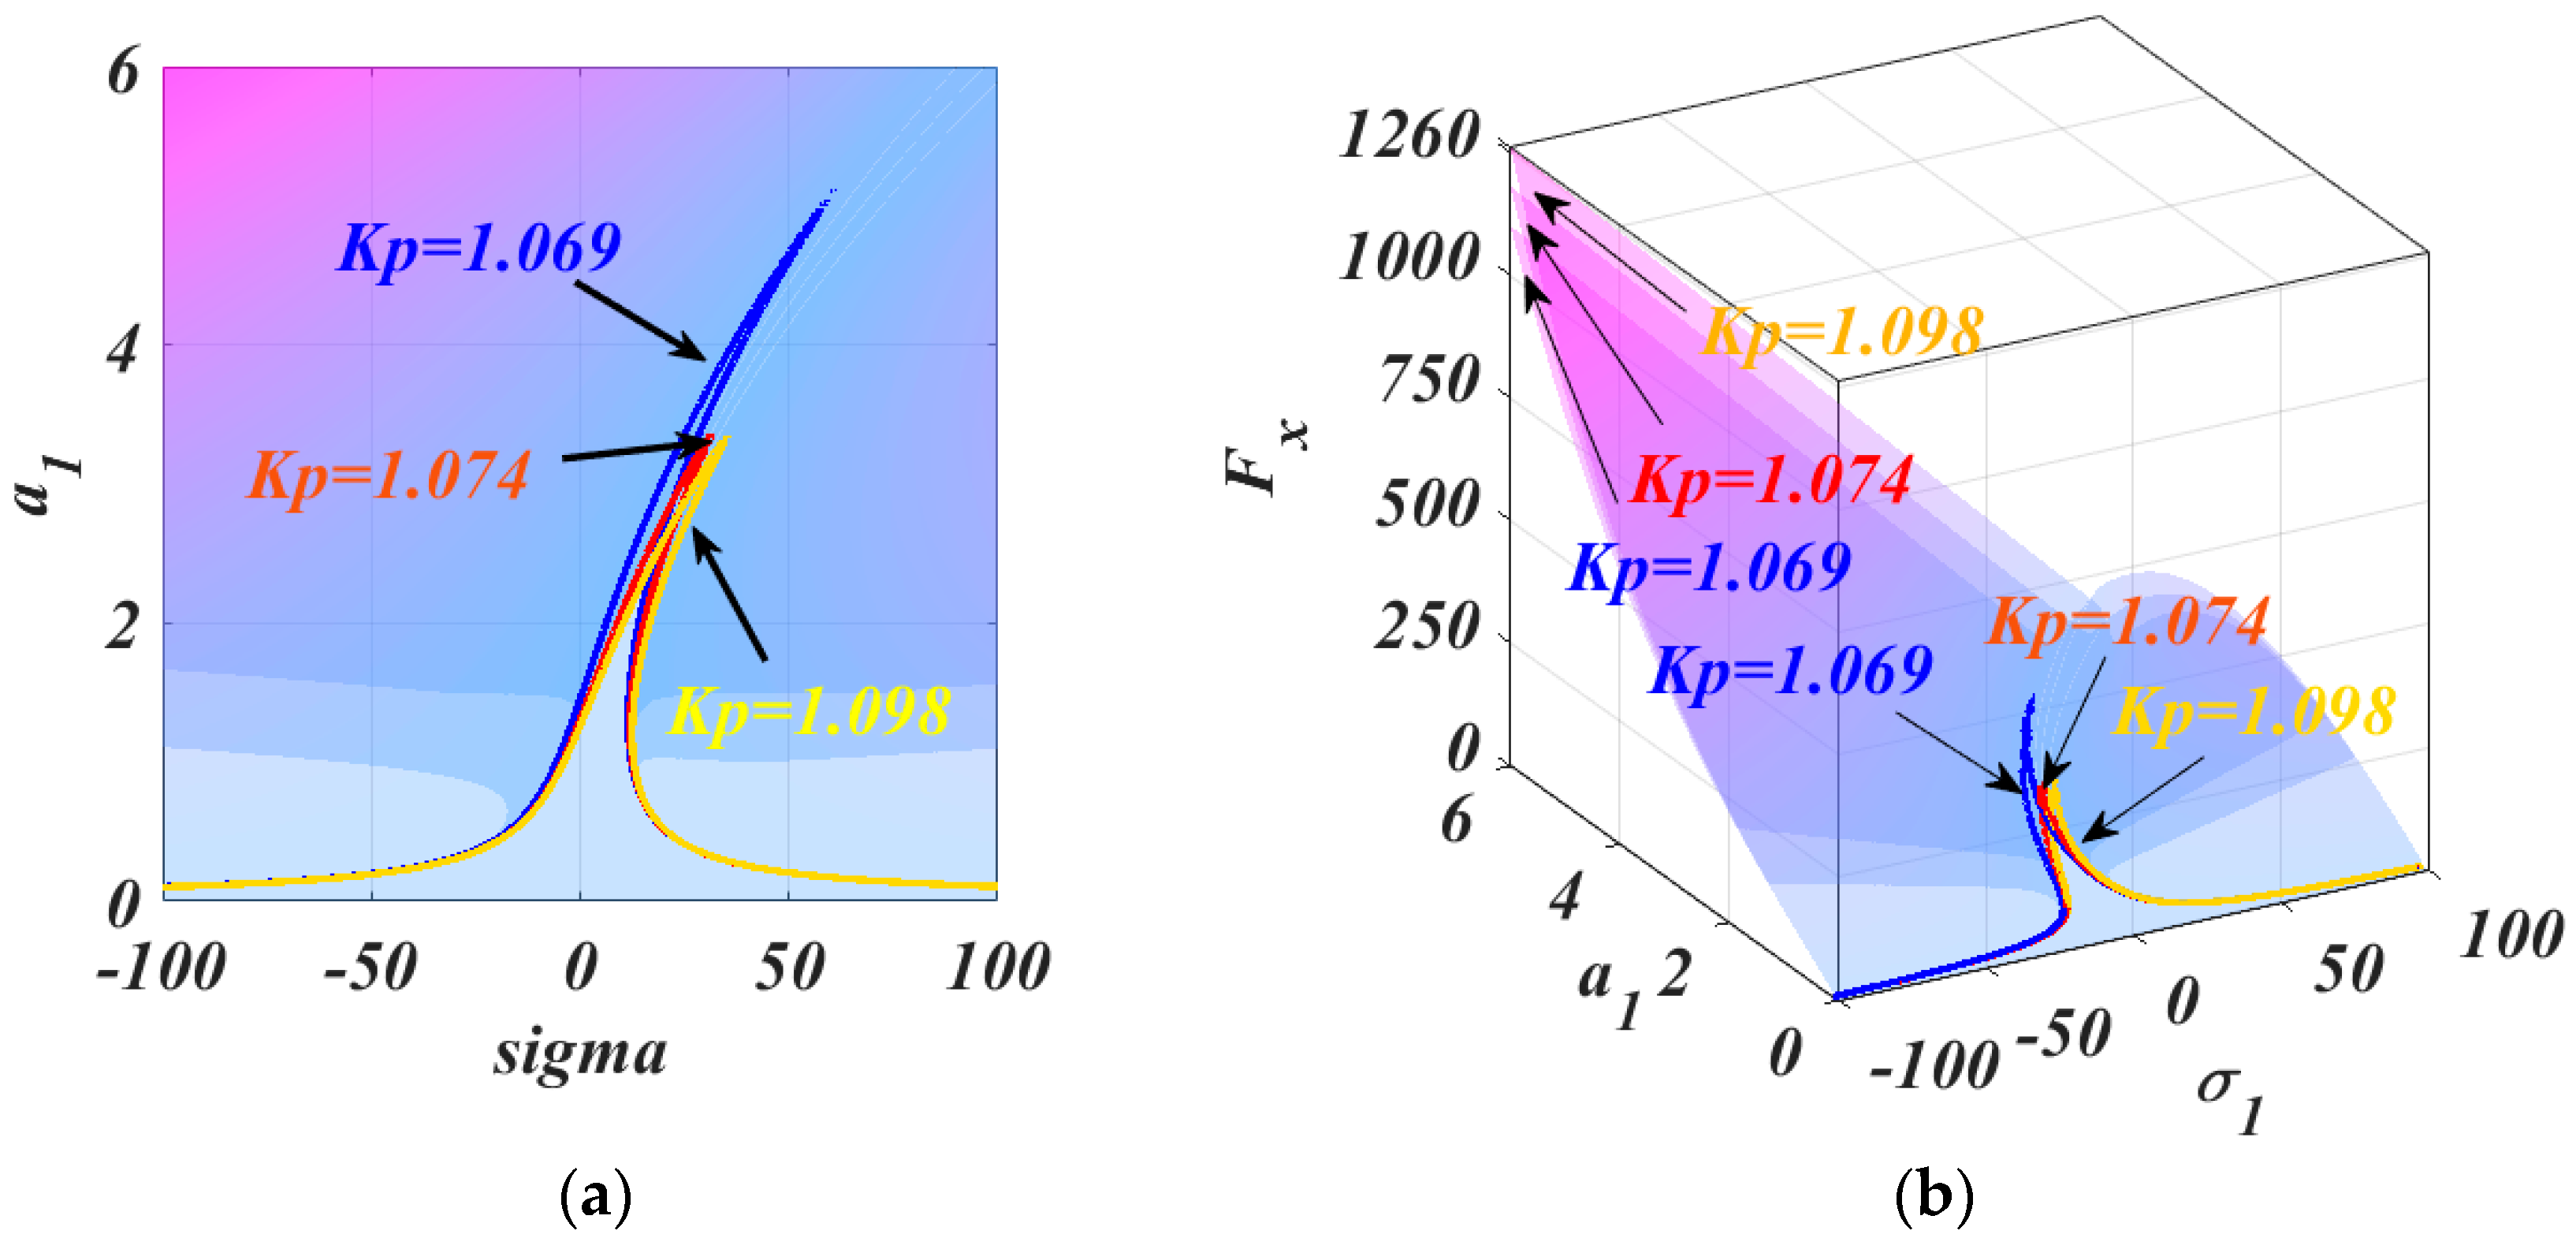
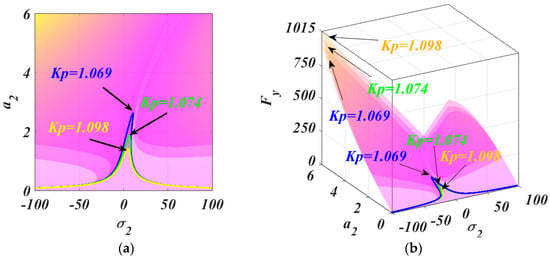
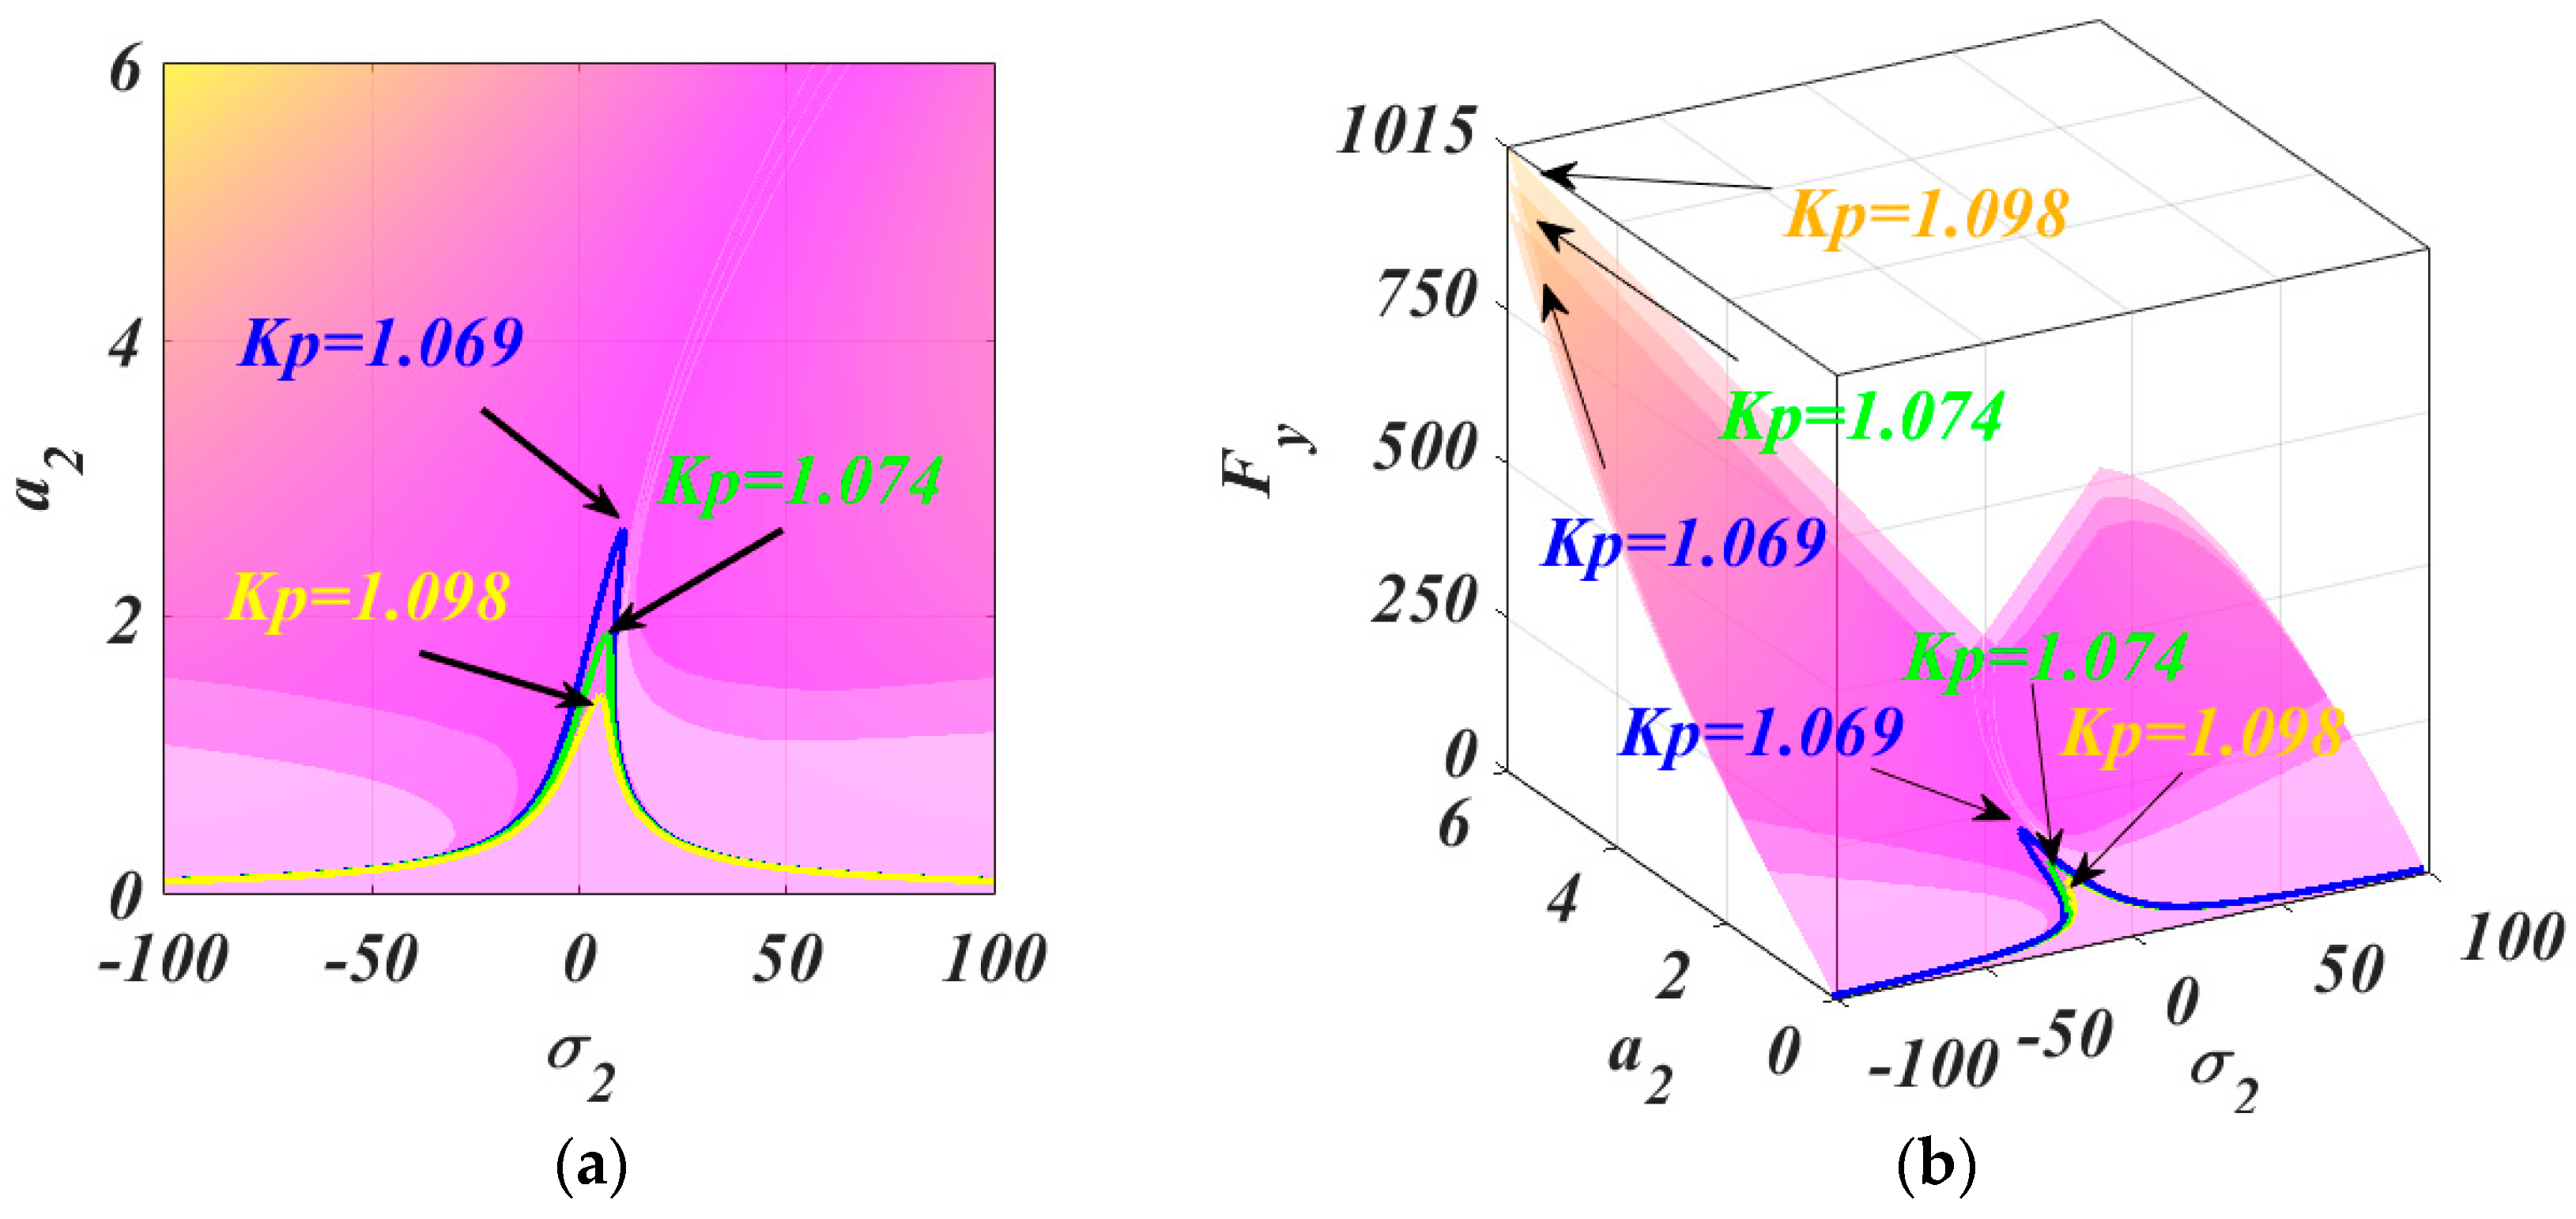
Figure 3, Figure 4, Figure 5 and Figure 6 show the curves of the relationship between the excitation and magnitude-frequency response, where , , , , , and . By substituting the initial values into Equations (14) and (15) and then substituting the algebraic values into Equations (52) and (53), the plots are generated using Equations (52) and (53).
Figure 3.
The influence of different proportional coefficients under the first-order mode: (a) curve of the amplitude-frequency response relationship, (b) curve of the relationship between excitation and amplitude-frequency response.
Figure 4.
The influence of different proportional coefficients under the second-order mode: (a) curve of the amplitude-frequency response relationship, (b) curve of the relationship between excitation and amplitude-frequency response.
Figure 5.
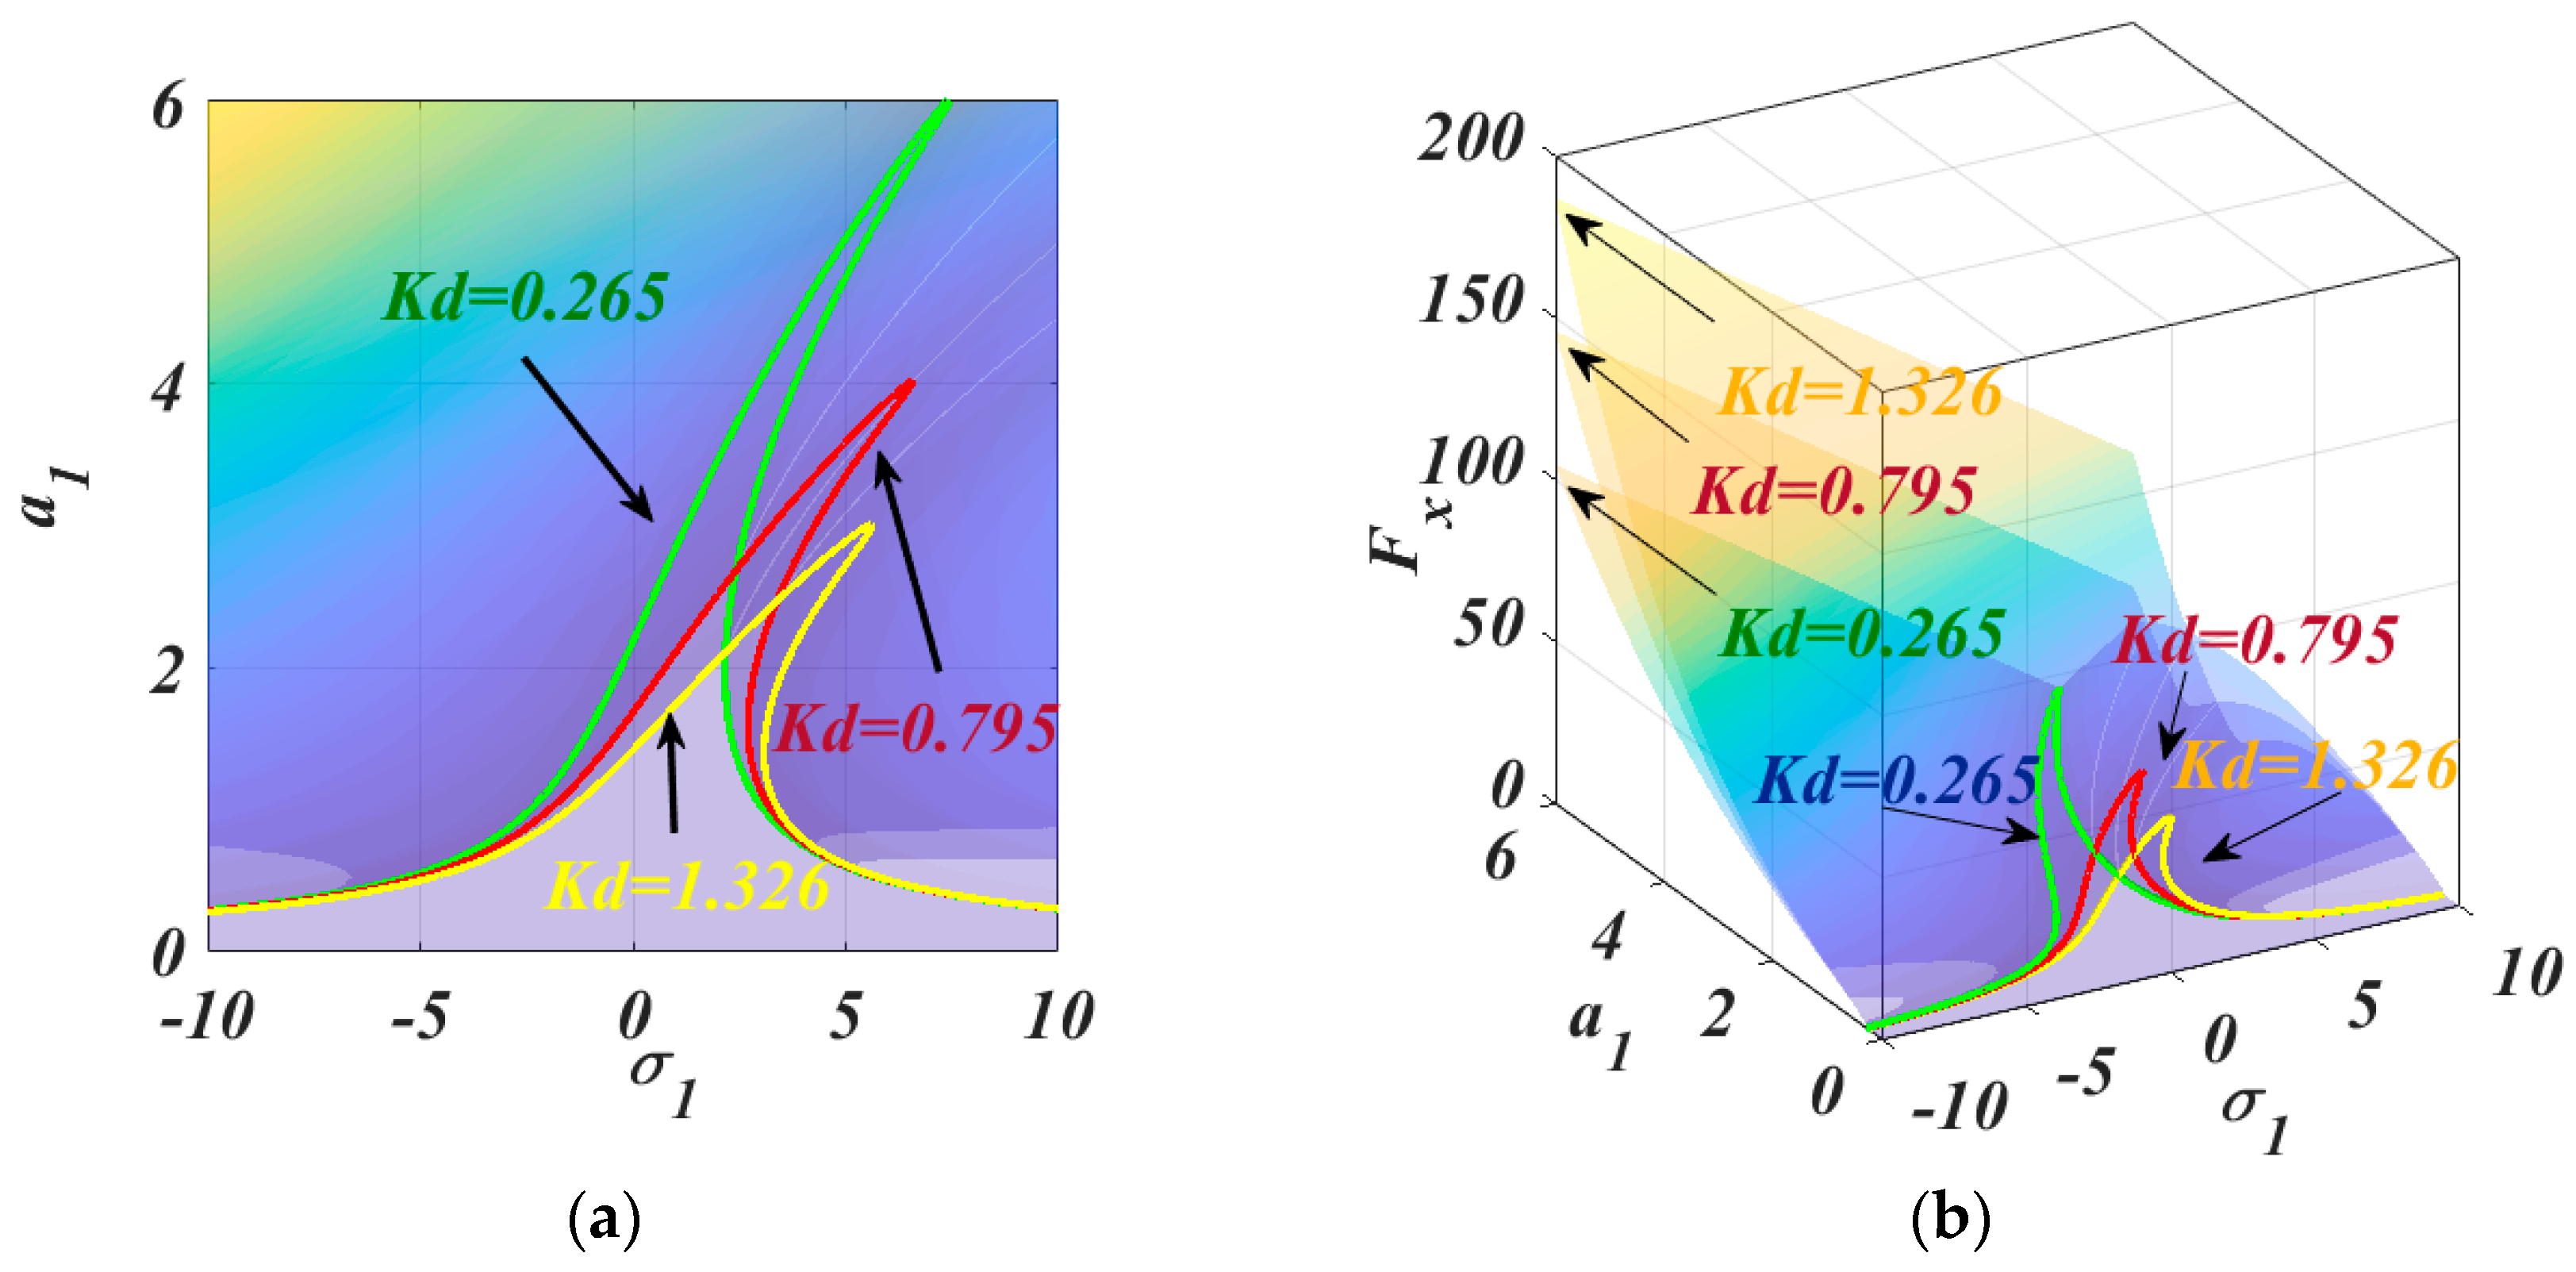
The influence of different differential gains under the first-order mode: (a) curve of the amplitude-frequency response relationship, (b) curve of the relationship between excitation and amplitude-frequency response.
Figure 6.
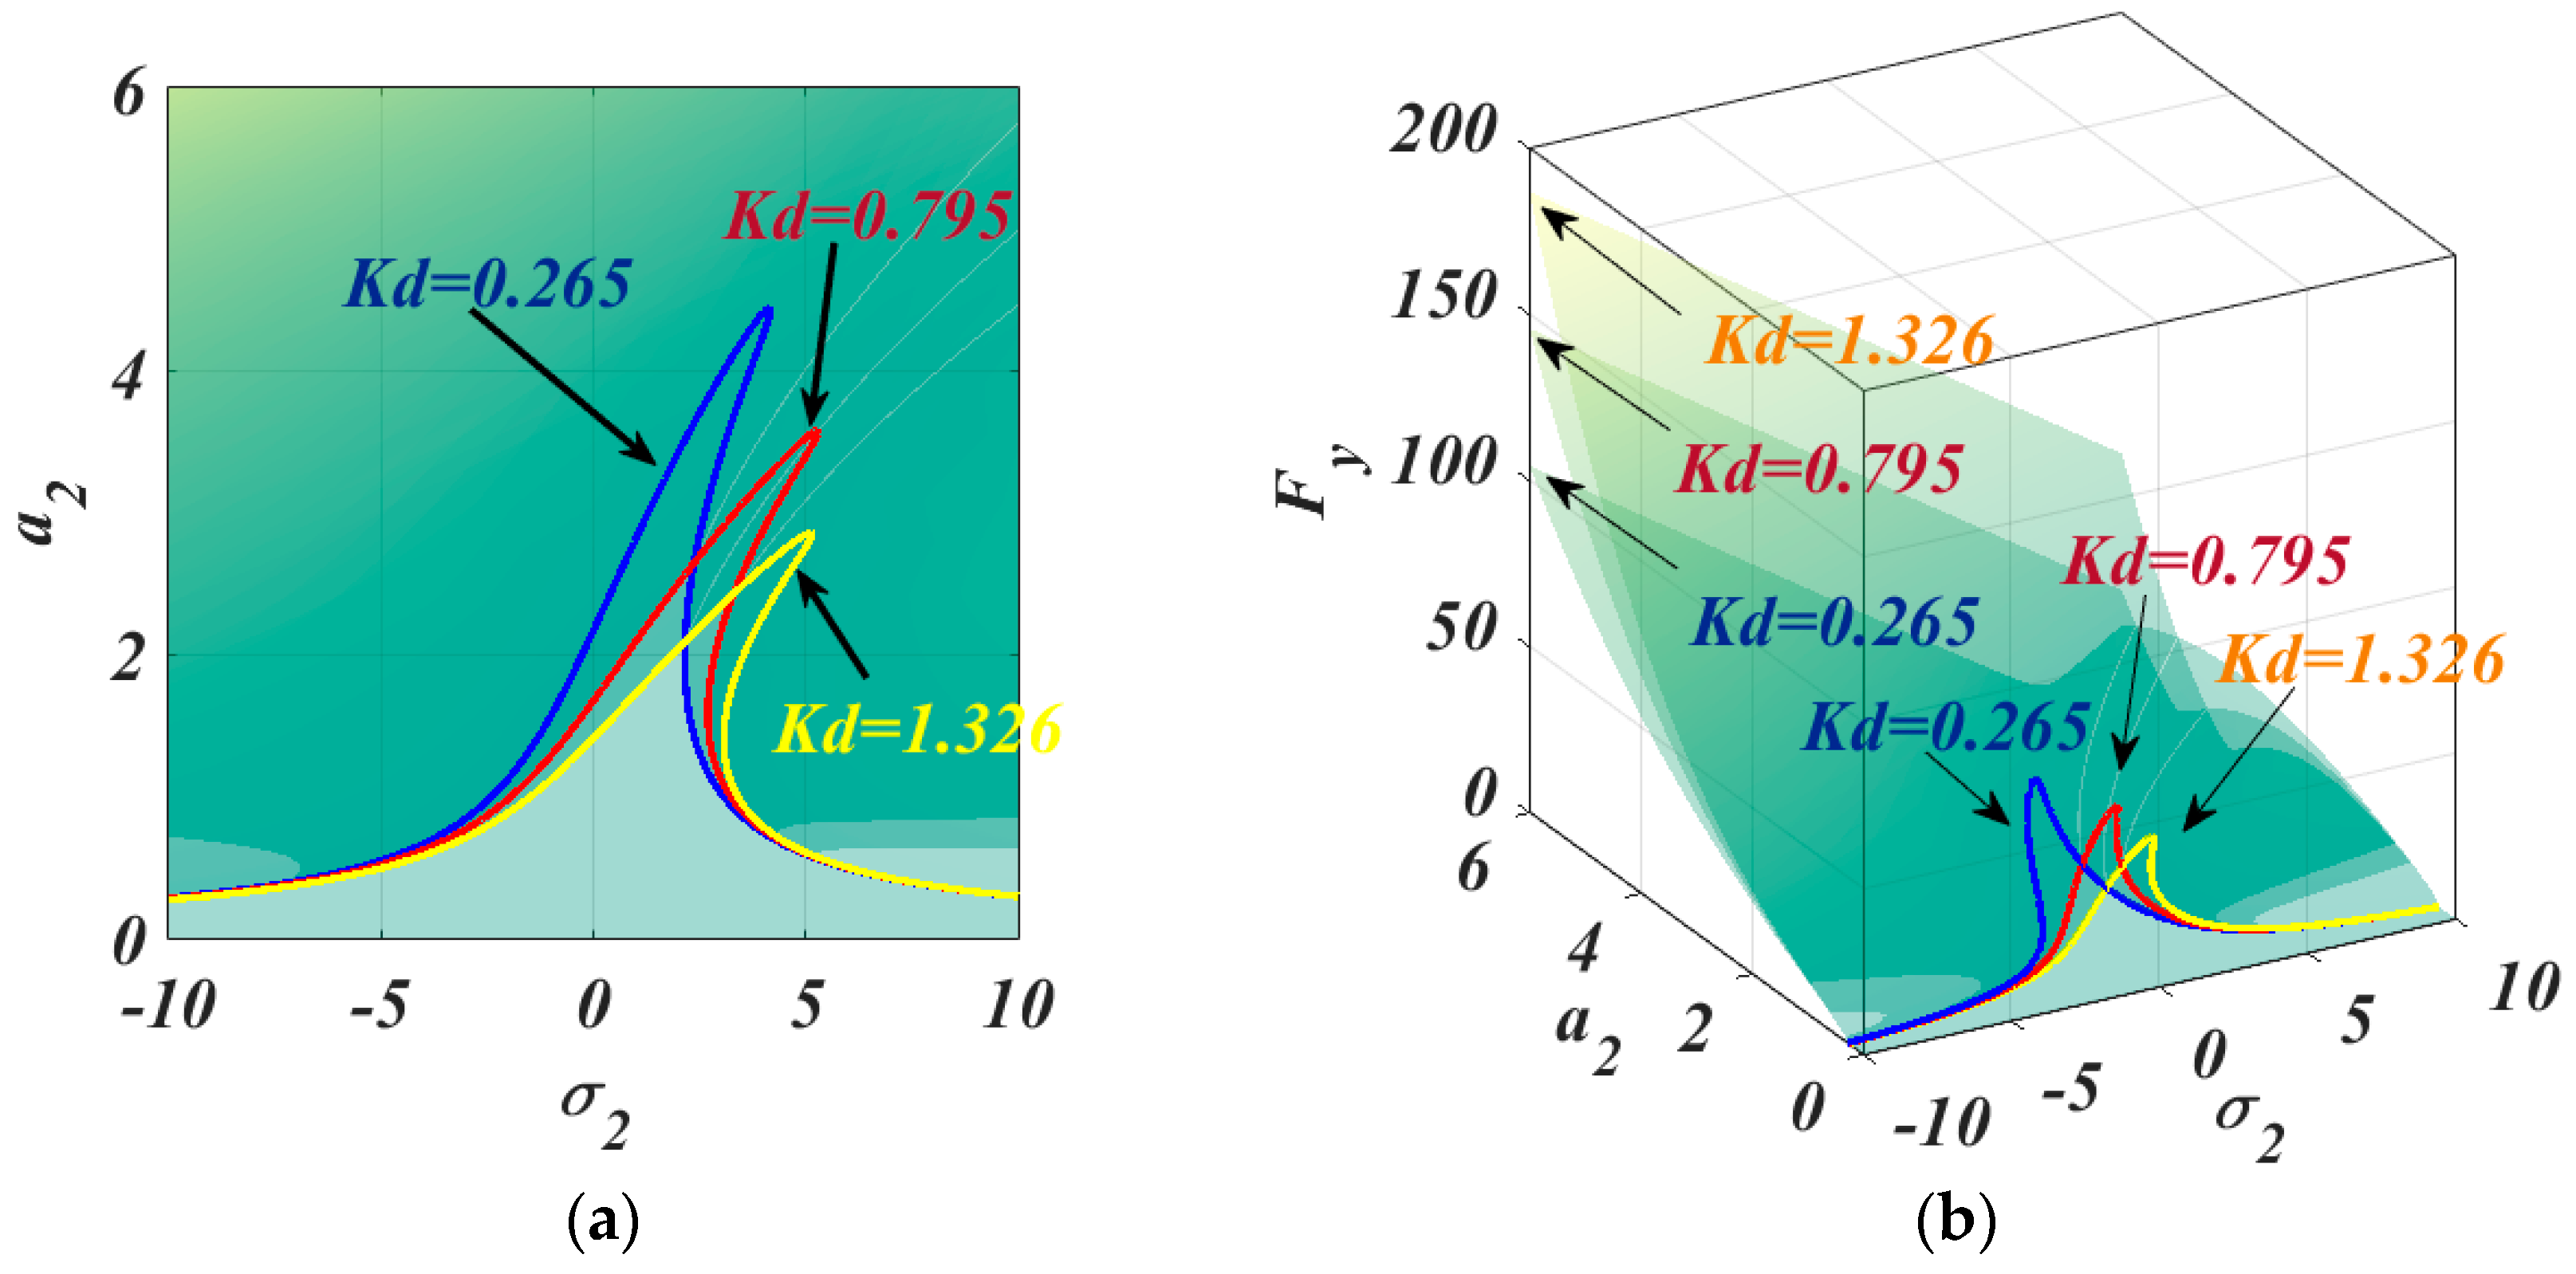
The influence of different differential gains under the second-order mode: (a) curve of the amplitude-frequency response relationship, (b) curve of the relationship between excitation and amplitude-frequency response.
Figure 3 shows the magnitude-frequency response curve of the first-order mode of the bearing system. With the derivative gain fixed at 0.415, the proportional coefficient is made to be a variable. As can be observed from Figure 3a, as the proportional coefficient increases, the resonance peak of the magnitude-frequency curve decreases, the curvature increases, and the hardening spring characteristic of the system intensifies. In other words, an increase in the proportional coefficient accelerates the system’s response speed to errors. In a control system, a faster response speed may indicate that the system can recover to a stable state or resist external disturbances more rapidly, thereby enhancing the system’s “stiffness” to a certain extent. This demonstrates that the proportional coefficient can adjust both the amplitude of the system’s response and its hardening/softening spring characteristics. Figure 3b illustrates the three-dimensional curve representing the relationship between the electromagnetic force and the magnitude-frequency response for the first-order mode of the system. As can be seen from Figure 3b, as the proportional coefficient increases, the electromagnetic force of the system also increases. In other words, increasing the proportional coefficient can enhance the response speed and sensitivity of the system, enabling it to reach a stable state more quickly.
Figure 4 depicts the magnitude-frequency response curve for the second-order mode of the bearing system. From Figure 4, similar properties to Figure 3 can be observed, where as the scaling coefficient increases, the resonance peak of the amplitude frequency curve decreases. Comparing Figure 4a with Figure 3a, it can be noticed that under the same proportional coefficient , the resonance peak of the system’s first-order mode is higher than that of the second-order mode, and the nonlinear characteristic of the system’s first-order mode is stronger than that of the second-order mode. Similarly, it can be found from Figure 3b and Figure 4b that the electromagnetic force under the second-order mode is lower than that under the first-order mode.
Figure 5 depicts the magnitude-frequency characteristic curves for the system’s first-order mode under varying differential gain . The proportional coefficient is fixed, and the differential gain is set as a variable. As shown in Figure 5a, under different differential gains , the resonance region of the system remains the same. Moreover, as the differential gain increases, the resonance peak of the system decreases, and the hardening spring characteristic is enhanced. In Figure 5b, it is observed that the larger the differential gain , the greater the electromagnetic force acting on the system.
Figure 6 illustrates the magnitude-frequency characteristic curves for the system’s second-order mode under varying differential gain . As seen in Figure 6a, under different differential gains , the system exhibits hardening spring characteristics consistently. Notably, the resonance peak of the system’s second-order mode is significantly lower than that of the first-order mode. Furthermore, the magnitudes of the electromagnetic forces and under the first-order and second-order modes of the system are similar.
4.2. Influence of PD Control on Rotor Motion Trajectory
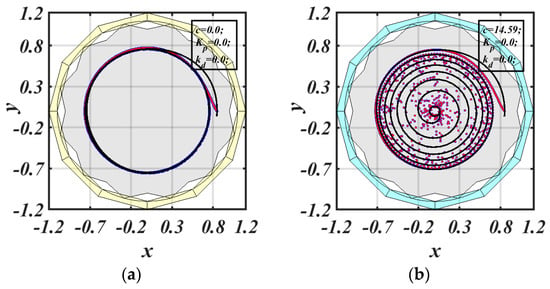
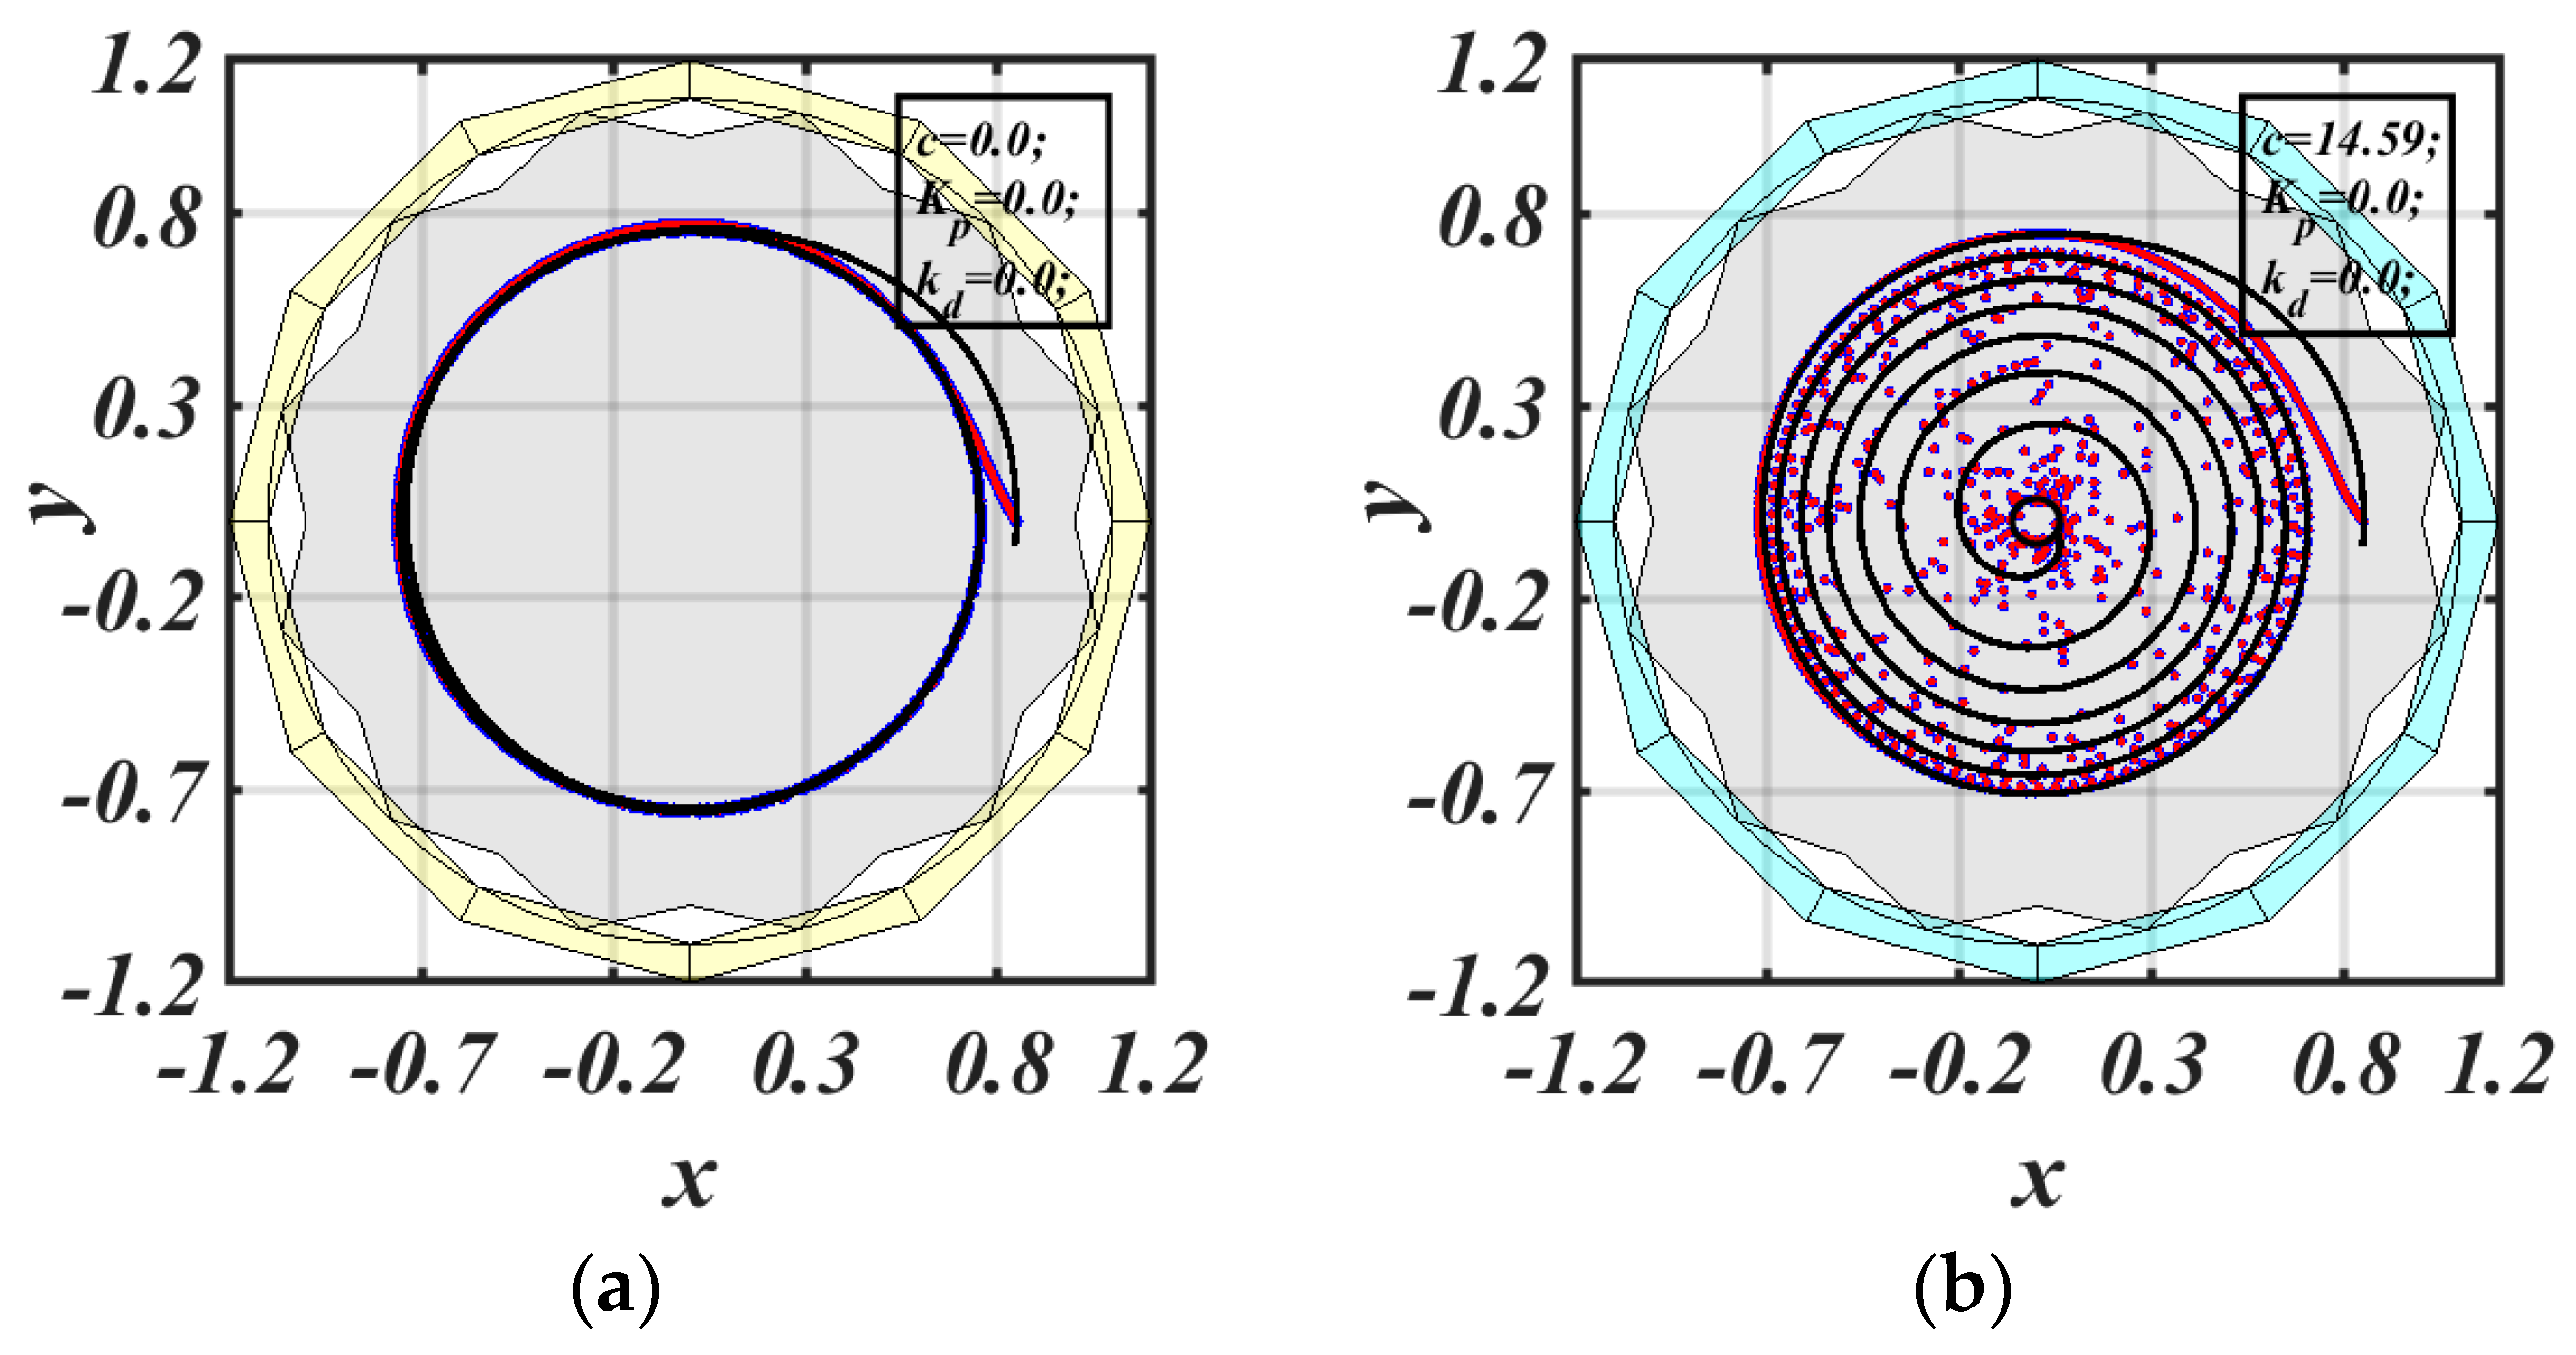
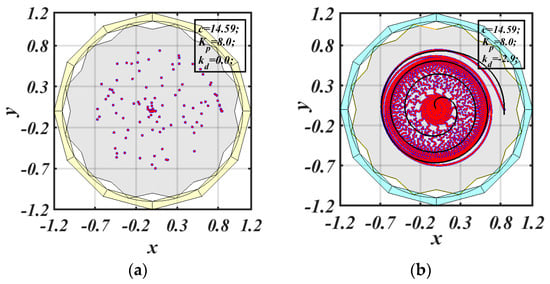
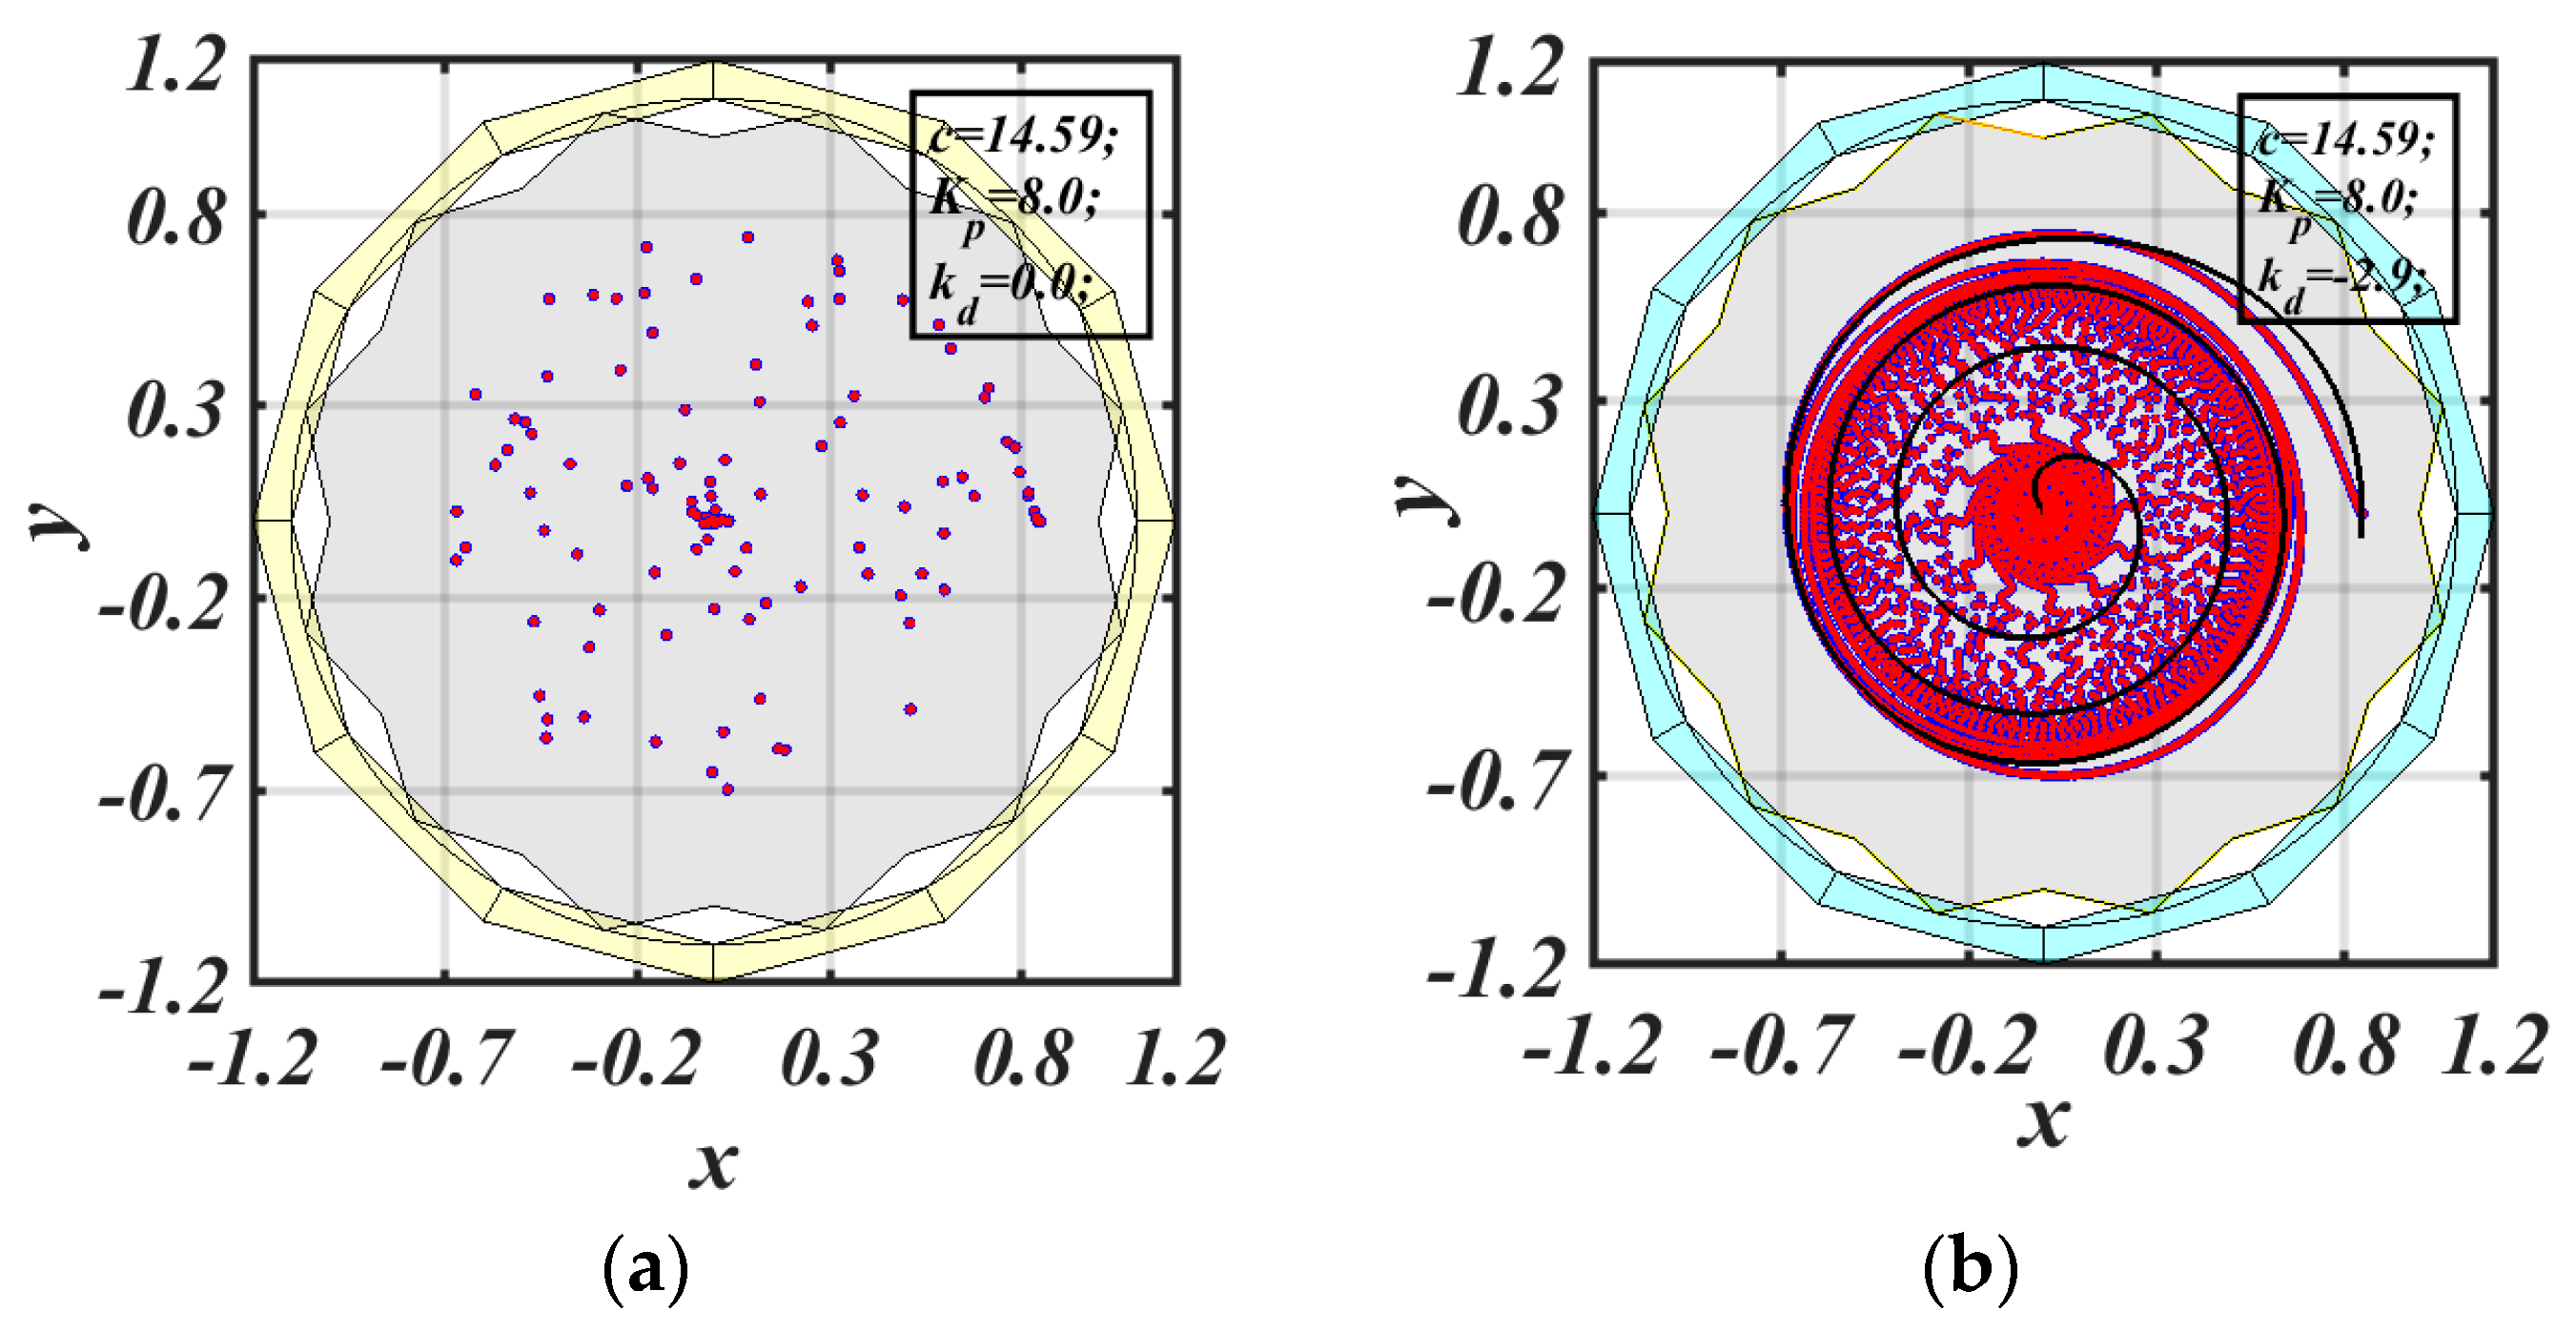
For evaluating the performance of the PD controller, the most intuitive method is to observe the changes in the rotor trajectory. By analyzing these trajectories, we can effectively assess the PD controller’s ability to maintain a stable operation of the rotor. Figure 7 and Figure 8 show the rotor displacement plots obtained through numerical simulations of the four-dimensional averaged equations in the polar coordinate system from Equations (41) –(44). We set , , , , , and , with , , , as the initial values.
Figure 7.
Rotor motion trajectory plots: (a) motion trajectory position without damping and without controller involvement, (b) motion trajectory position with varying damping coefficients without PD control involvement.
Figure 8.
Rotor motion trajectory plots: (a) motion trajectory position under control with only the proportional coefficient involved, (b) motion trajectory position under control with both the proportional coefficient and the differential gain involved.
Figure 7a shows the rotor’s motion trajectory in a two-dimensional coordinate system under conditions without damping and without the involvement of PD control; Figure 7b shows the rotor’s motion trajectory with varying damping coefficients but without the involvement of PD control. In Figure 7, the black line represents a specific rotor motion trajectory, and the colored dots represent the rotor’s position at various time points. From Figure 7a, we can observe that the actual position of the rotor always deviates from the origin, and the motion trajectory indicated by the black line continuously rotates around the origin, revealing that the rotor fails to remain at a fixed position. In Figure 7b, it can be seen that the rotor’s position predominantly deviates along two rings outside the equilibrium point. Additionally, we find that its motion trajectory tends to indefinitely approach one of the rings near the equilibrium point, forming a semi-stable limit cycle. Figure 7 indicates the instability of the 12-pole active magnetic bearing system’s motion under conditions without damping and without PD control, whereas the system exhibits a certain level of stability in its motion state under conditions with damping but without PD control.
Figure 8a,b simulate the two-dimensional rotor motion trajectories of the 12-pole active magnetic bearing system under PD control. The red dot represents the center-of-mass position of the rotor, and the black line represents its path. Figure 8a shows the effect of varying the proportional coefficient on the rotor’s motion trajectory, while Figure 8b shows the effect of varying the differential gain on the rotor’s motion trajectory. From Figure 8a, it can be seen that when the differential gain is not applied in the control, the rotor’s position changes rapidly, and the process is very unstable. From Figure 8b, it can be seen that the rotor’s final position approaches the equilibrium point, with its motion trajectory tending toward the equilibrium point, which is a stable focus at this point. Comparing Figure 8b with Figure 7b, it is found that the rotor with a differential gain system mainly vibrates near the origin compared to the system without differential gain.
In summary, under no-damping conditions, the rotor’s motion usually circles around the edge of the magnetic bearing housing and cannot become stable; with the introduction of damping control, the rotor’s motion becomes semi-stable; the introduction of the proportional coefficient can accelerate the rotor’s rate of change but also increases the instability of the change process; the introduction of the differential gain enhances the stability of the motion. This indicates that the simultaneous involvement of both and in the PD controller significantly improves the stability of the rotor’s motion.
4.3. The Influence of PD Control on System Energy
With the introduction of the damping system and the PD control system, the 12-pole active magnetic bearing becomes a non-conservative system, and its energy is no longer conserved. Therefore, it is necessary to study the impact of PD control on the energy changes in the bearing system.
In a conservative case, the relationship between the amplitude and energy can be obtained, where is the total energy when without disturbance:
Further introducing the ratio of the energy in the direction to the total energy gives the following:
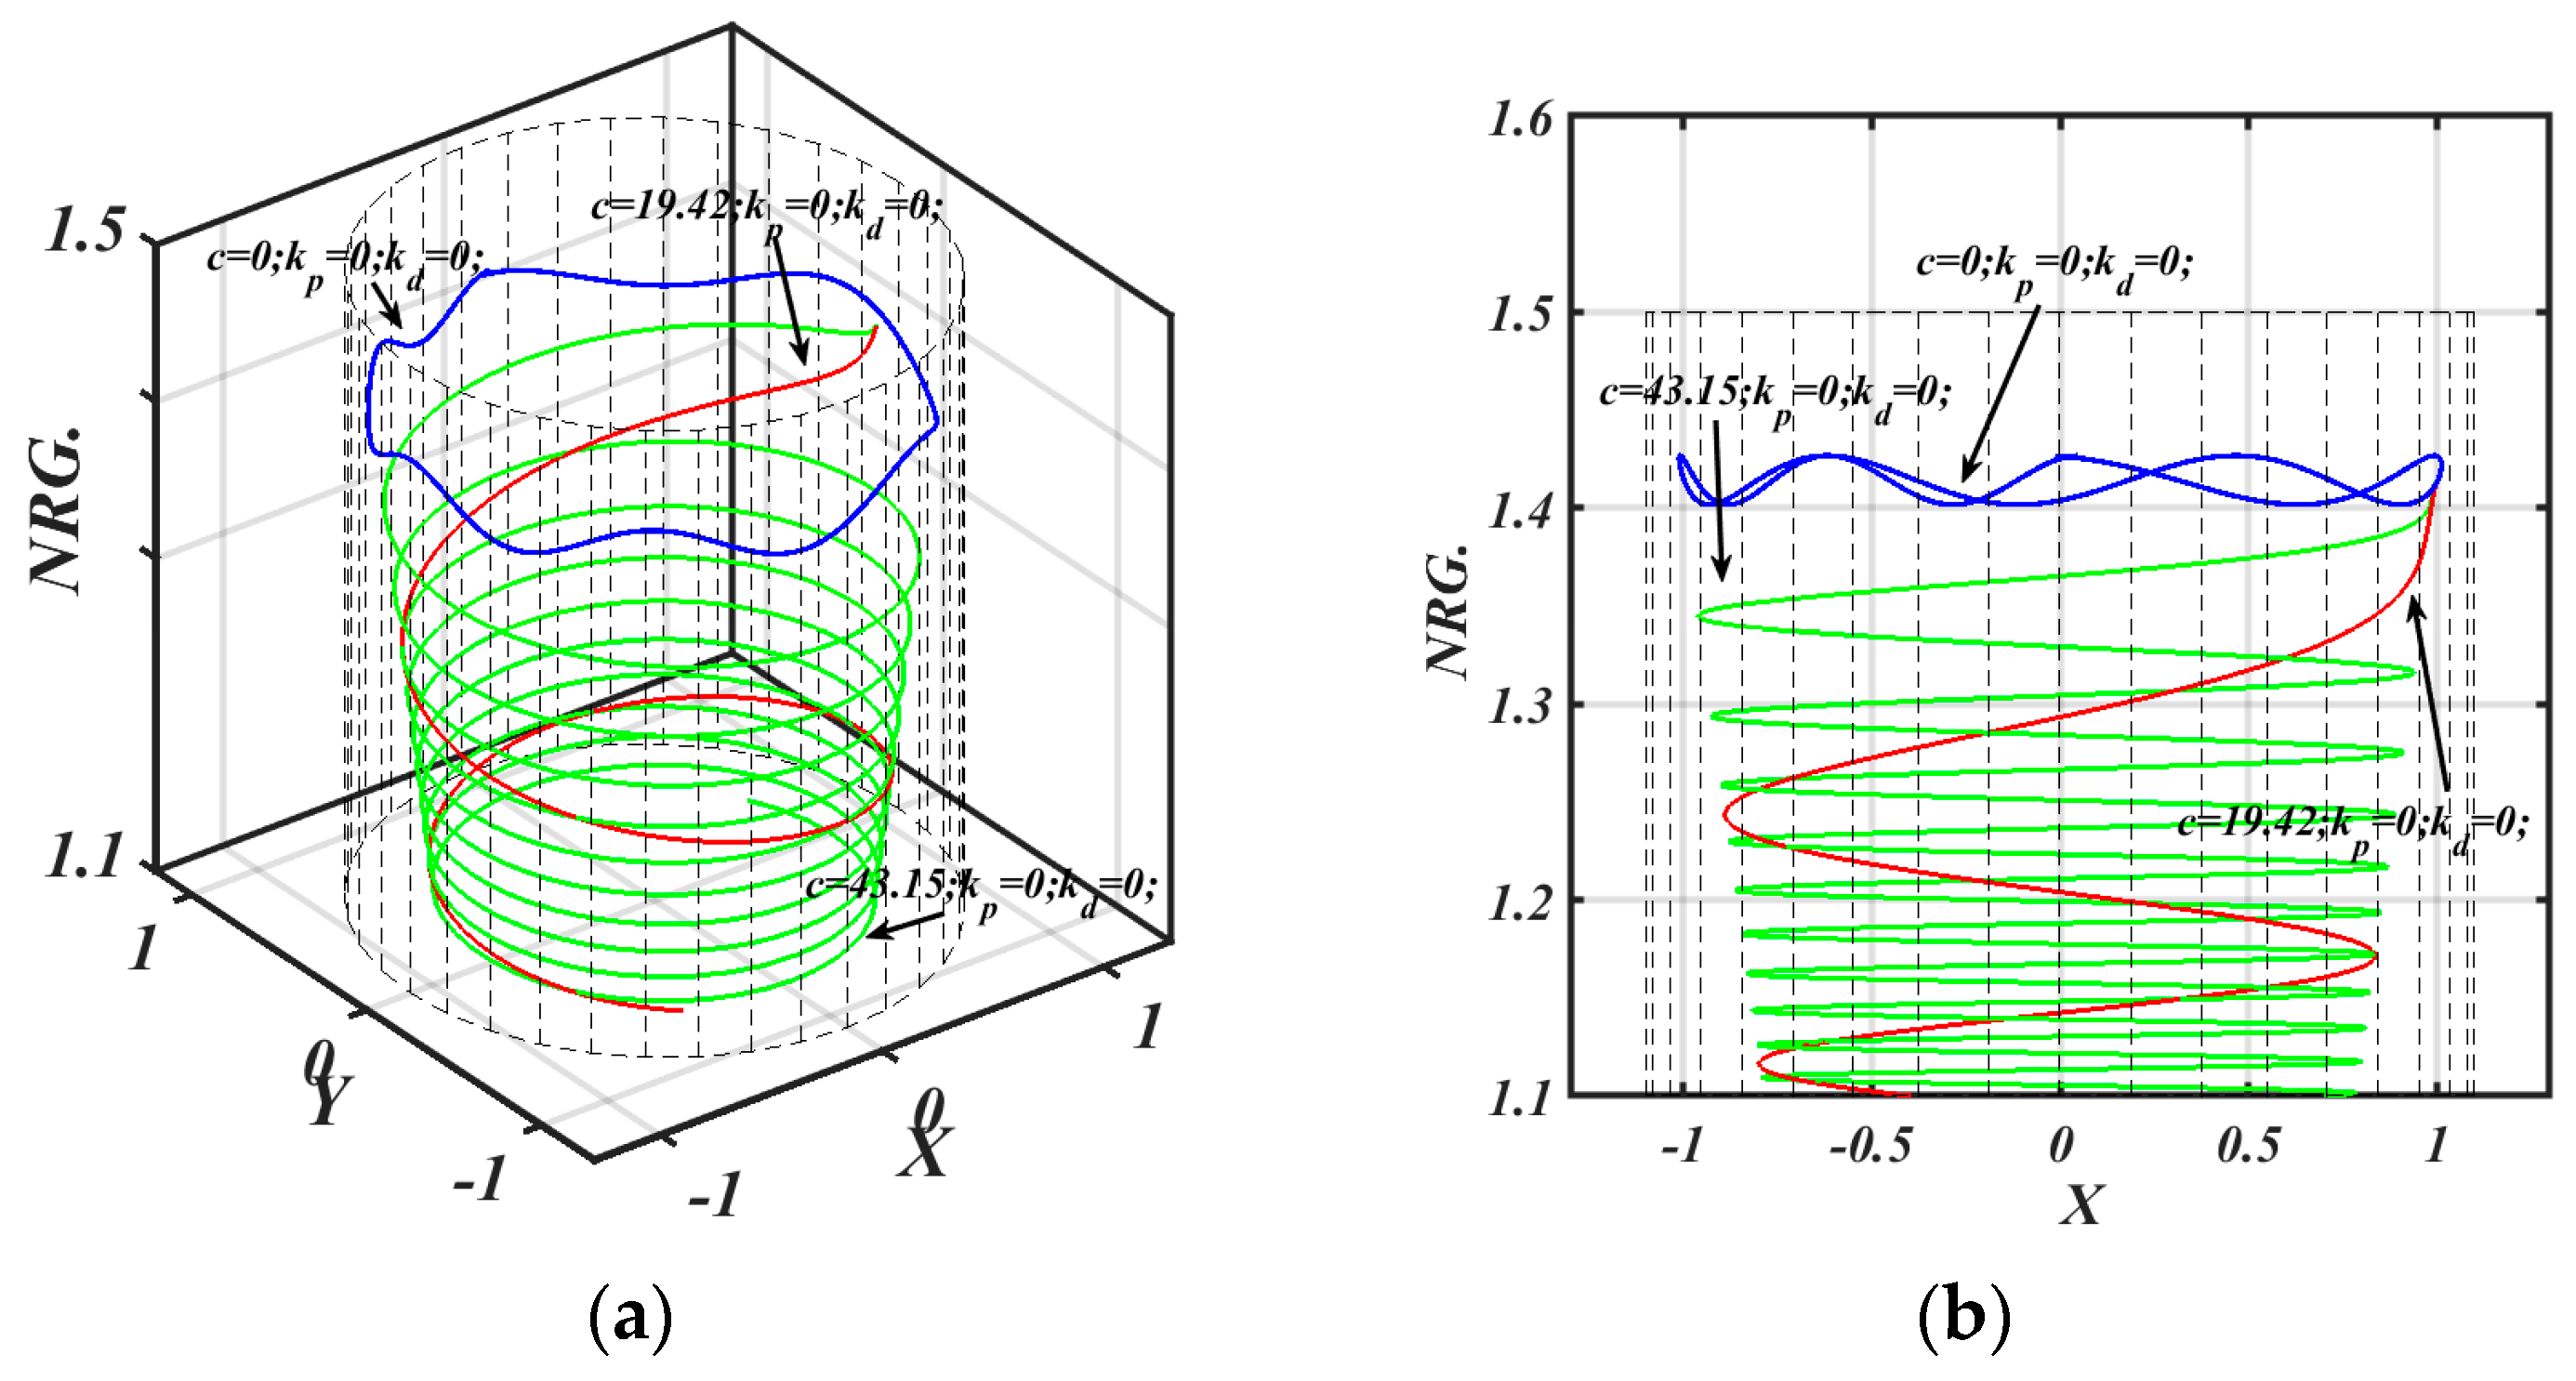
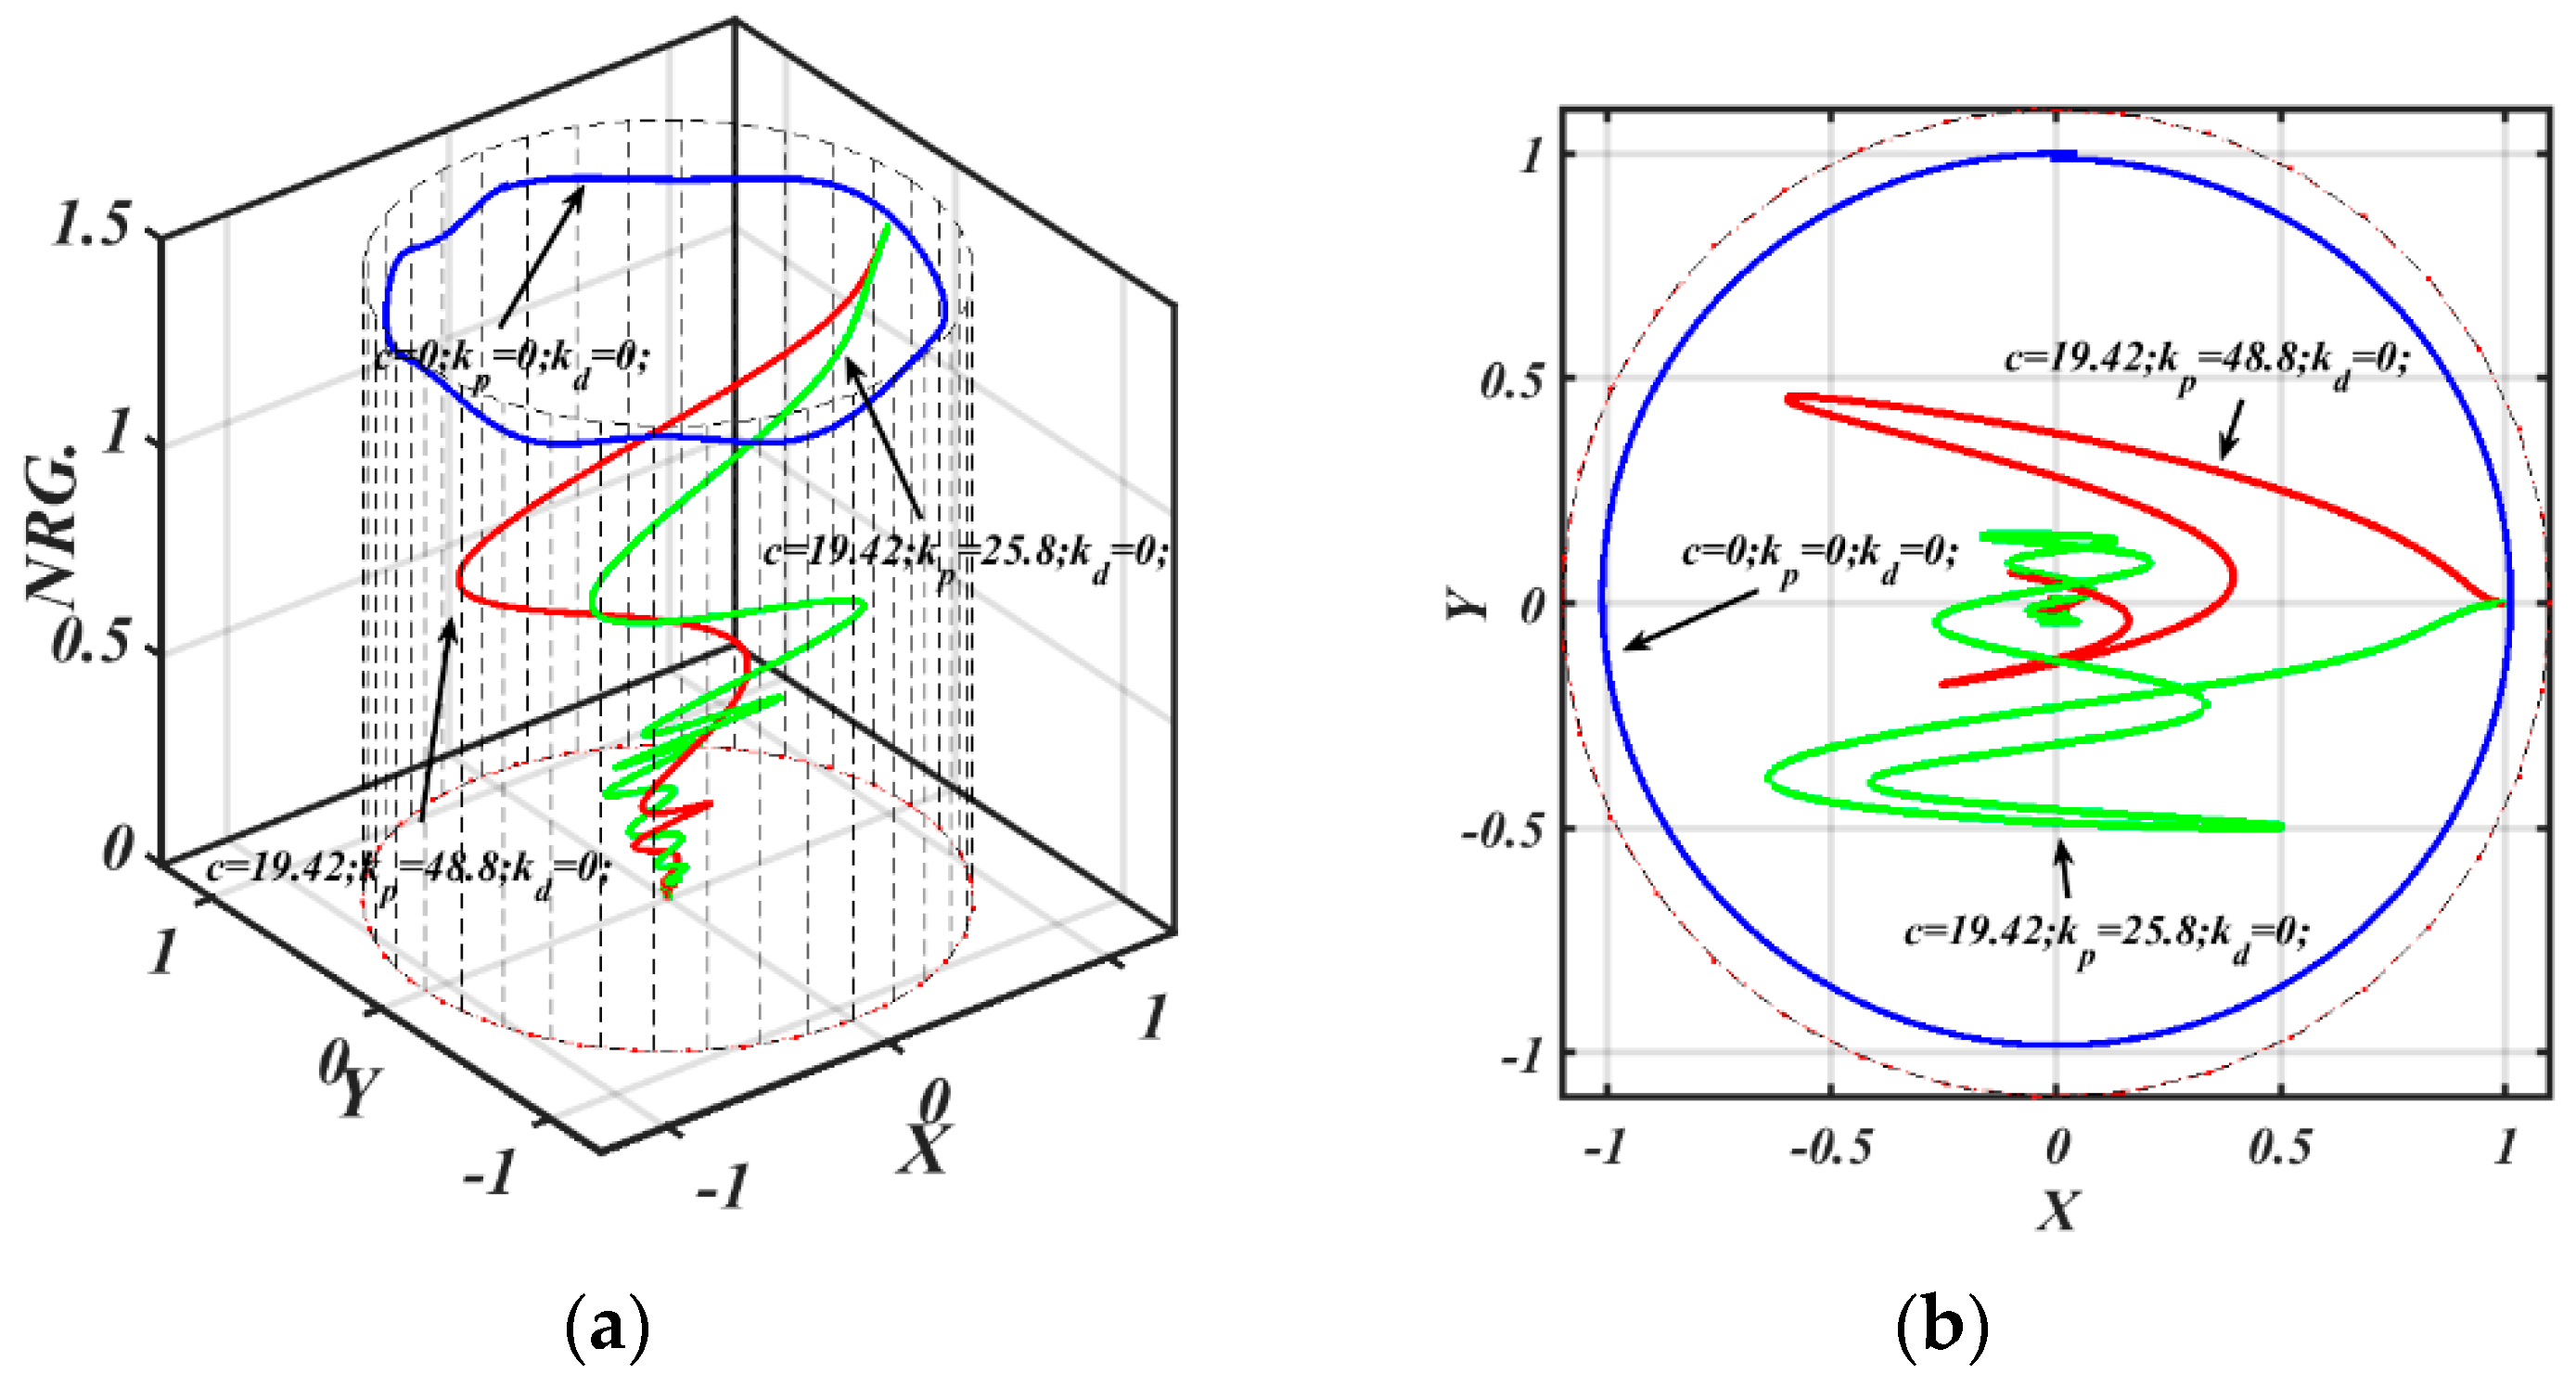
In Figure 9, Figure 10 and Figure 11, we analyze the amplitude variations and their impact on the energy ratio in the 12-pole active magnetic bearing system under conditions of no damping and no control, varying damping coefficients, and applying a PD controller. Numerical simulations were performed using Equations (14), (15), (41)–(44), (54) and (55) to compare the results of the three different data sets. The -axis and -axis in Figure 9, Figure 10 and Figure 11 show the amplitude variations, while the -axis reflects the energy ratio. The parameters were set as , , , , , and .
Figure 9.
The effect of different damping conditions on the system’s energy and amplitude: (a) the impact of in three-dimensional coordinates , (b) the impact of in the plane .
Figure 10.
The effect of different control parameters: the impact of proportional coefficient on the system’s energy and amplitude: (a) the impact of in three-dimensional coordinates , (b) the impact of in the plane .
Figure 11.
The effect of different control parameters: the impact of differential gain on the system’s energy and amplitude: (a) the impact of in three-dimensional coordinates , (b) the impact of in the plane .
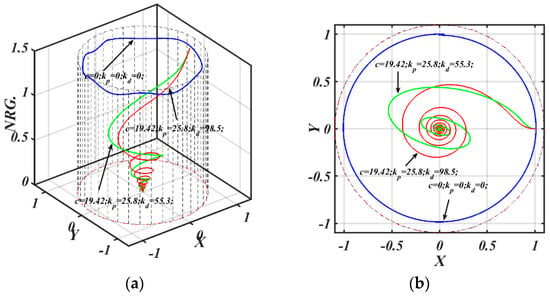
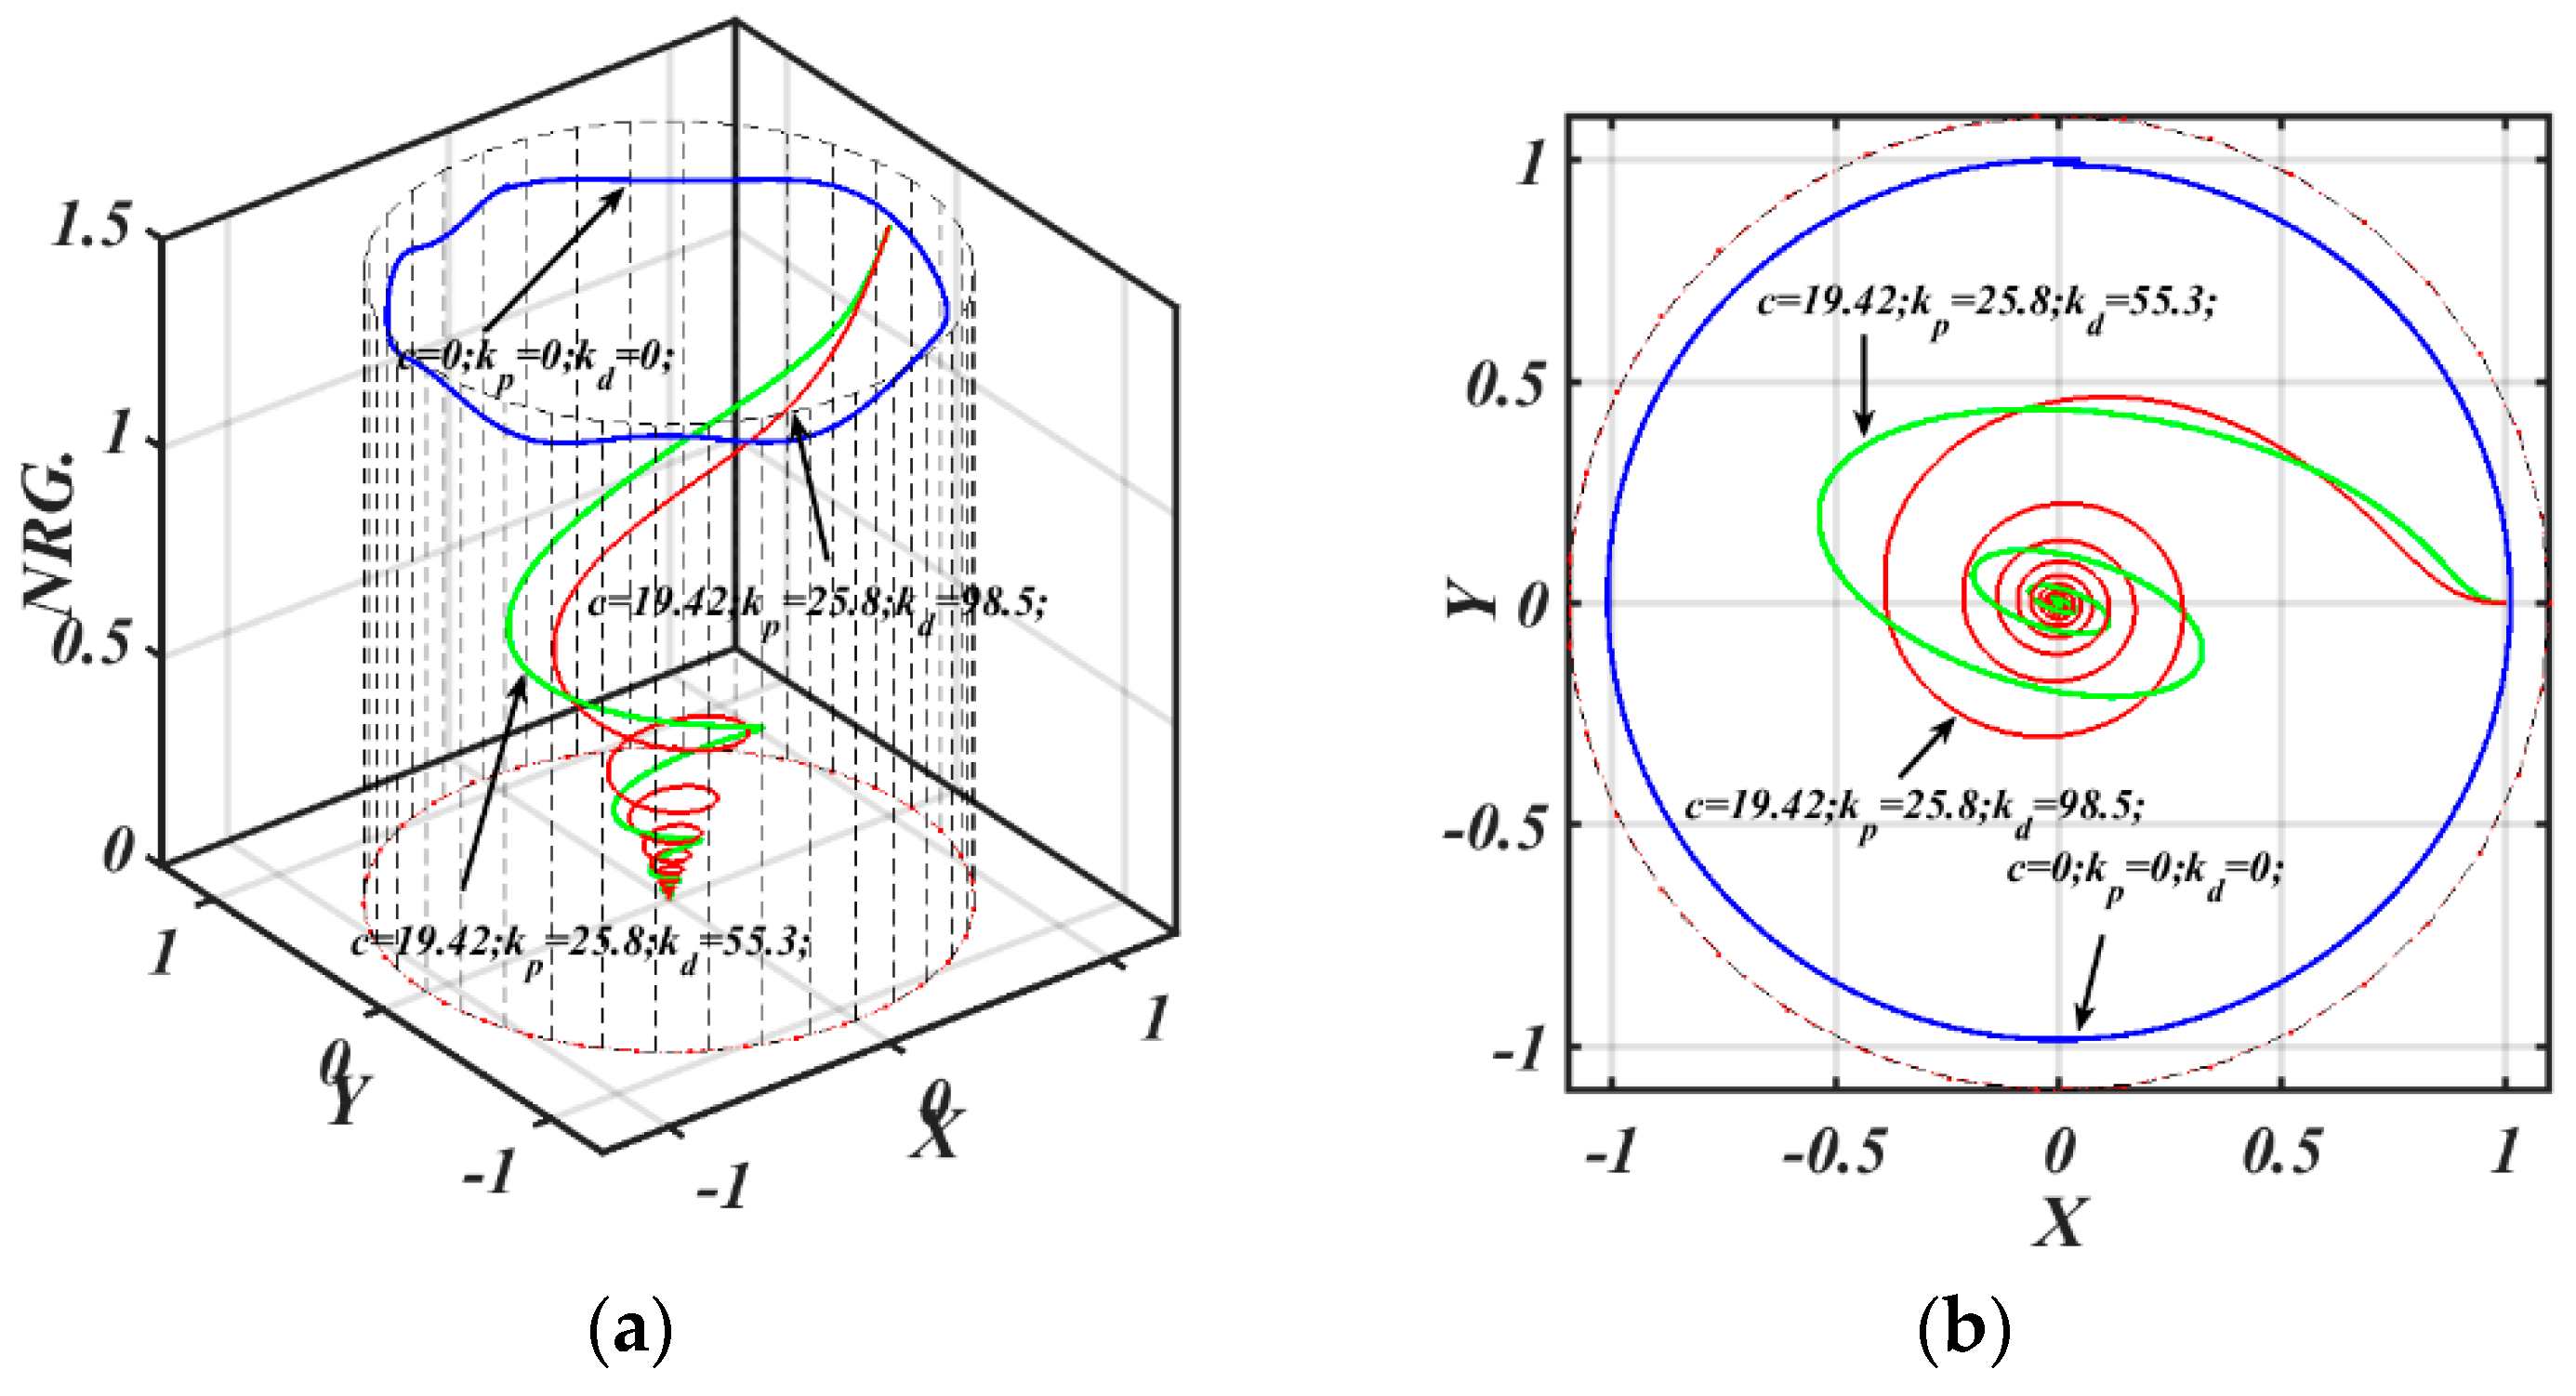
Figure 9 shows the amplitude and energy variation curves of the 12-pole rotor–active magnetic bearing system under different damping parameter conditions. The blue line represents the system’s behavior without damping and without controller involvement, while the red and green dashed lines represent the effects of different damping coefficients on the system. Figure 9a demonstrates that without damping, the system has no energy dissipation, and the amplitude in the and directions exhibits periodic changes. Figure 9b clearly indicates that increasing the damping coefficient can accelerate the system’s energy dissipation.
Figure 10 shows the effect of different proportional coefficients of the PD controller on the amplitude and energy of the 12-pole rotor–active magnetic bearing system. As shown in the three-dimensional plot in Figure 10a, it is easily observed that as the proportional coefficient increases, the system’s energy decays faster. The two-dimensional plot in Figure 10b indicates that the introduction of the proportional coefficient significantly suppresses the system’s amplitude. However, relatively large proportional coefficients might cause deviations in the amplitude of the system in the X and Y directions.
Figure 11 shows the effect of differential gain on the amplitude of and energy variation in the 12-pole rotor–active magnetic bearing system. From Figure 11a, it can be seen that with the introduction of the differential gain , the system’s energy gradually dissipates, and different values of have relatively small effects on the system’s amplitude in the and directions. Compared to Figure 9b, Figure 11b indicates that although the differential gain has a smaller impact on the system’s amplitude in the X and Y directions, it can adjust the deviations caused by the amplitude in the X and Y directions. As the value of increases, the system’s orderliness improves.
4.4. Global Dynamic Analysis under PD Control
The Runge-Kutta method is renowned for its high accuracy and stability. Compared with methods such as the Euler or Adams–Bashforth methods, it is very suitable for solving nonlinear system equations due to its superior error control [35]. In this article, in order to study the influence of PD control on the vibration of a 12-pole active magnetic bearing system, the proportional coefficient and differential gain are selected as control parameters while keeping other parameter values unchanged. The Runge-Kutta method is used to analyze the impact of the PD controller on the system’s stability. Next, numerical simulations are conducted using Equations (10), (11), (14), (15) and (47)–(49), and bifurcation diagrams, waveform diagrams, phase diagrams, and Poincaré maps are drawn to investigate the influence of PD controllers on the nonlinear vibration behavior of the system. First, we set , and we let be the variable to study the influence of the proportional coefficient on the system’s dynamic behavior. The selected parameters and initial conditions are as follows:
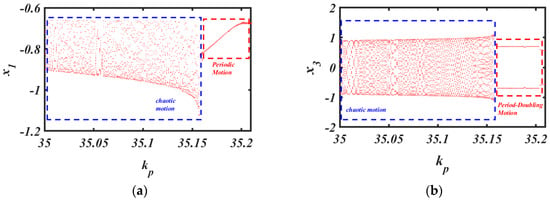
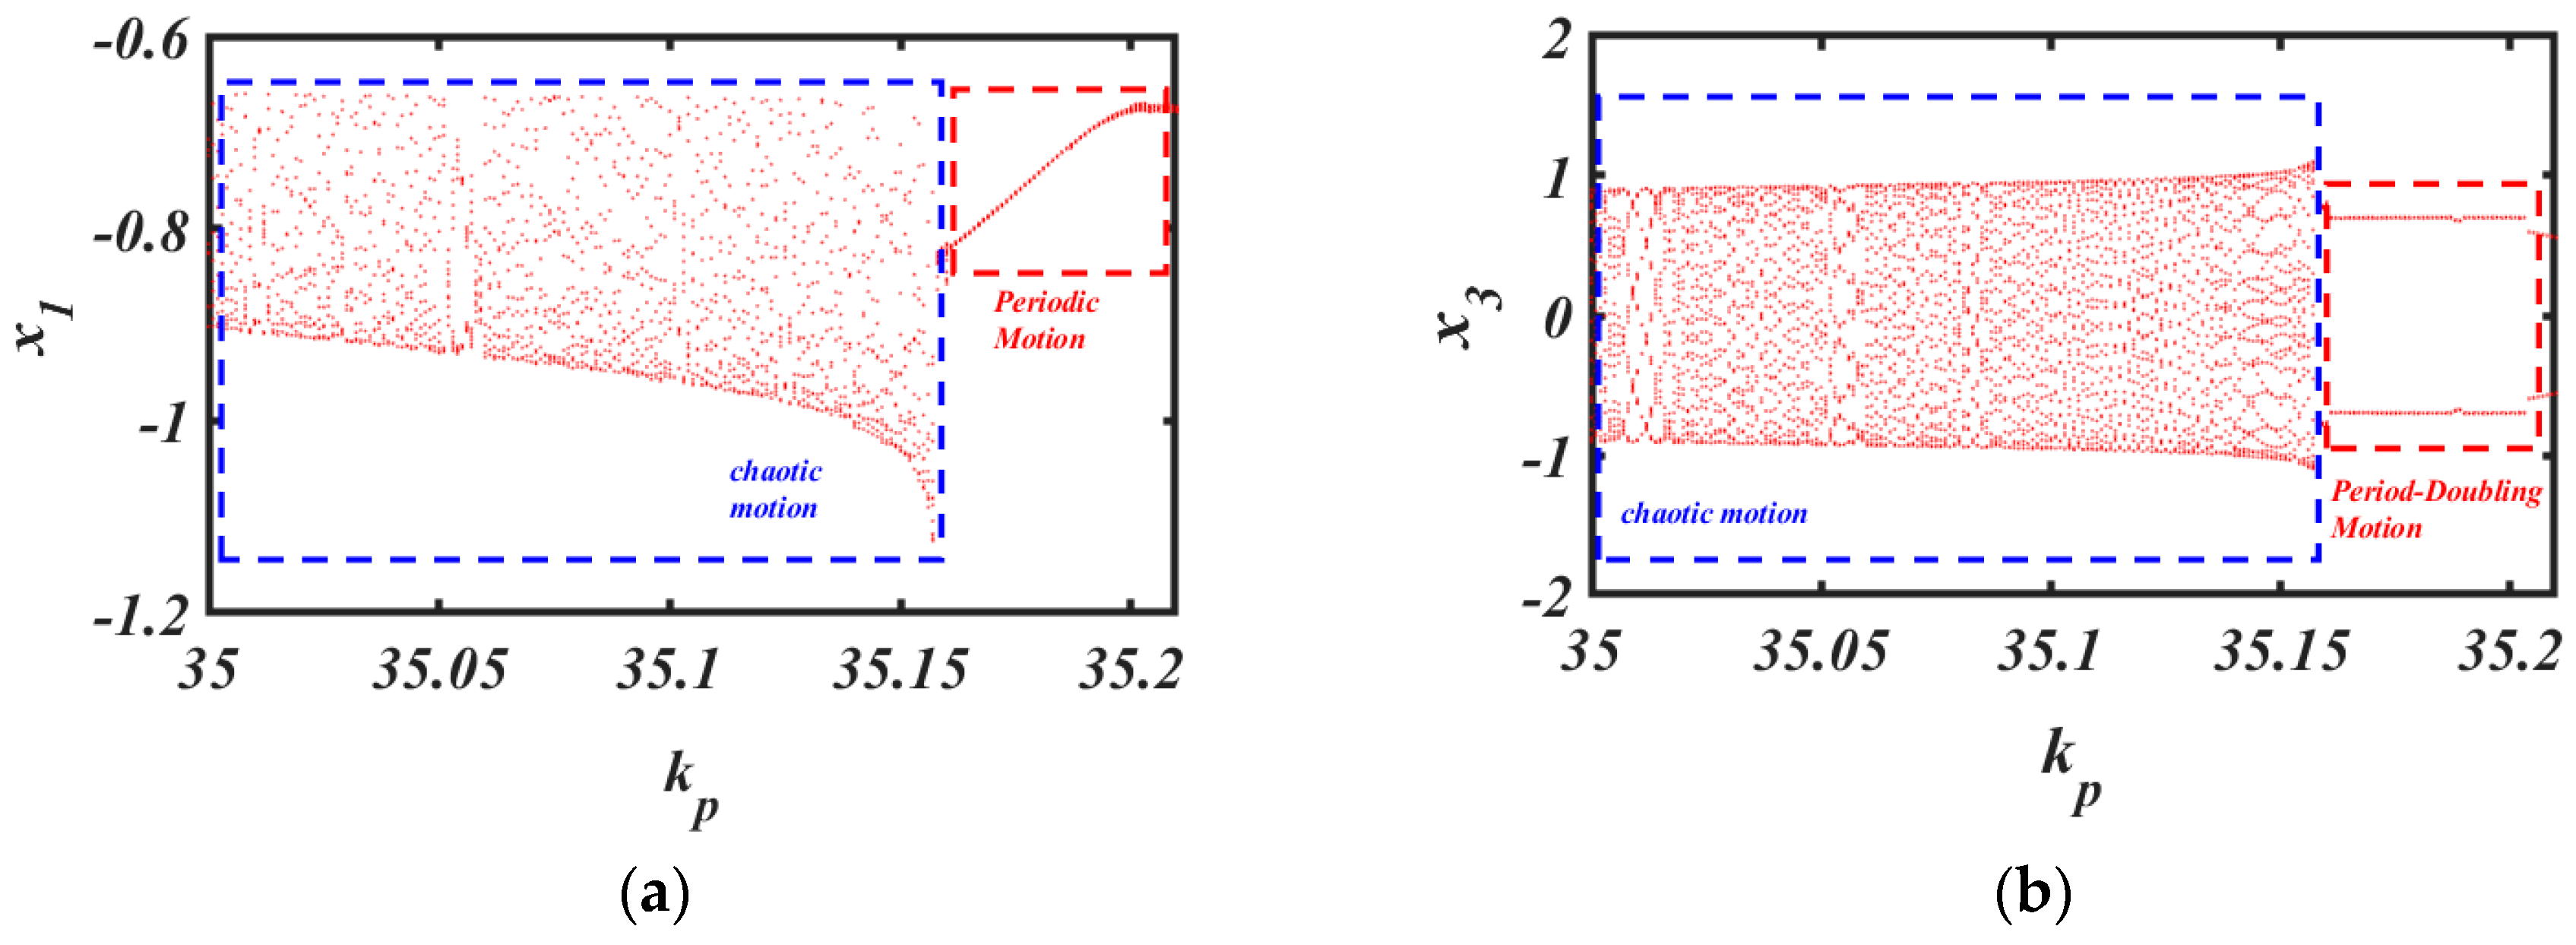
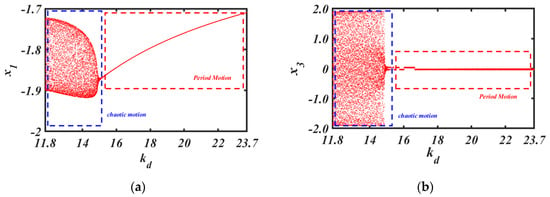
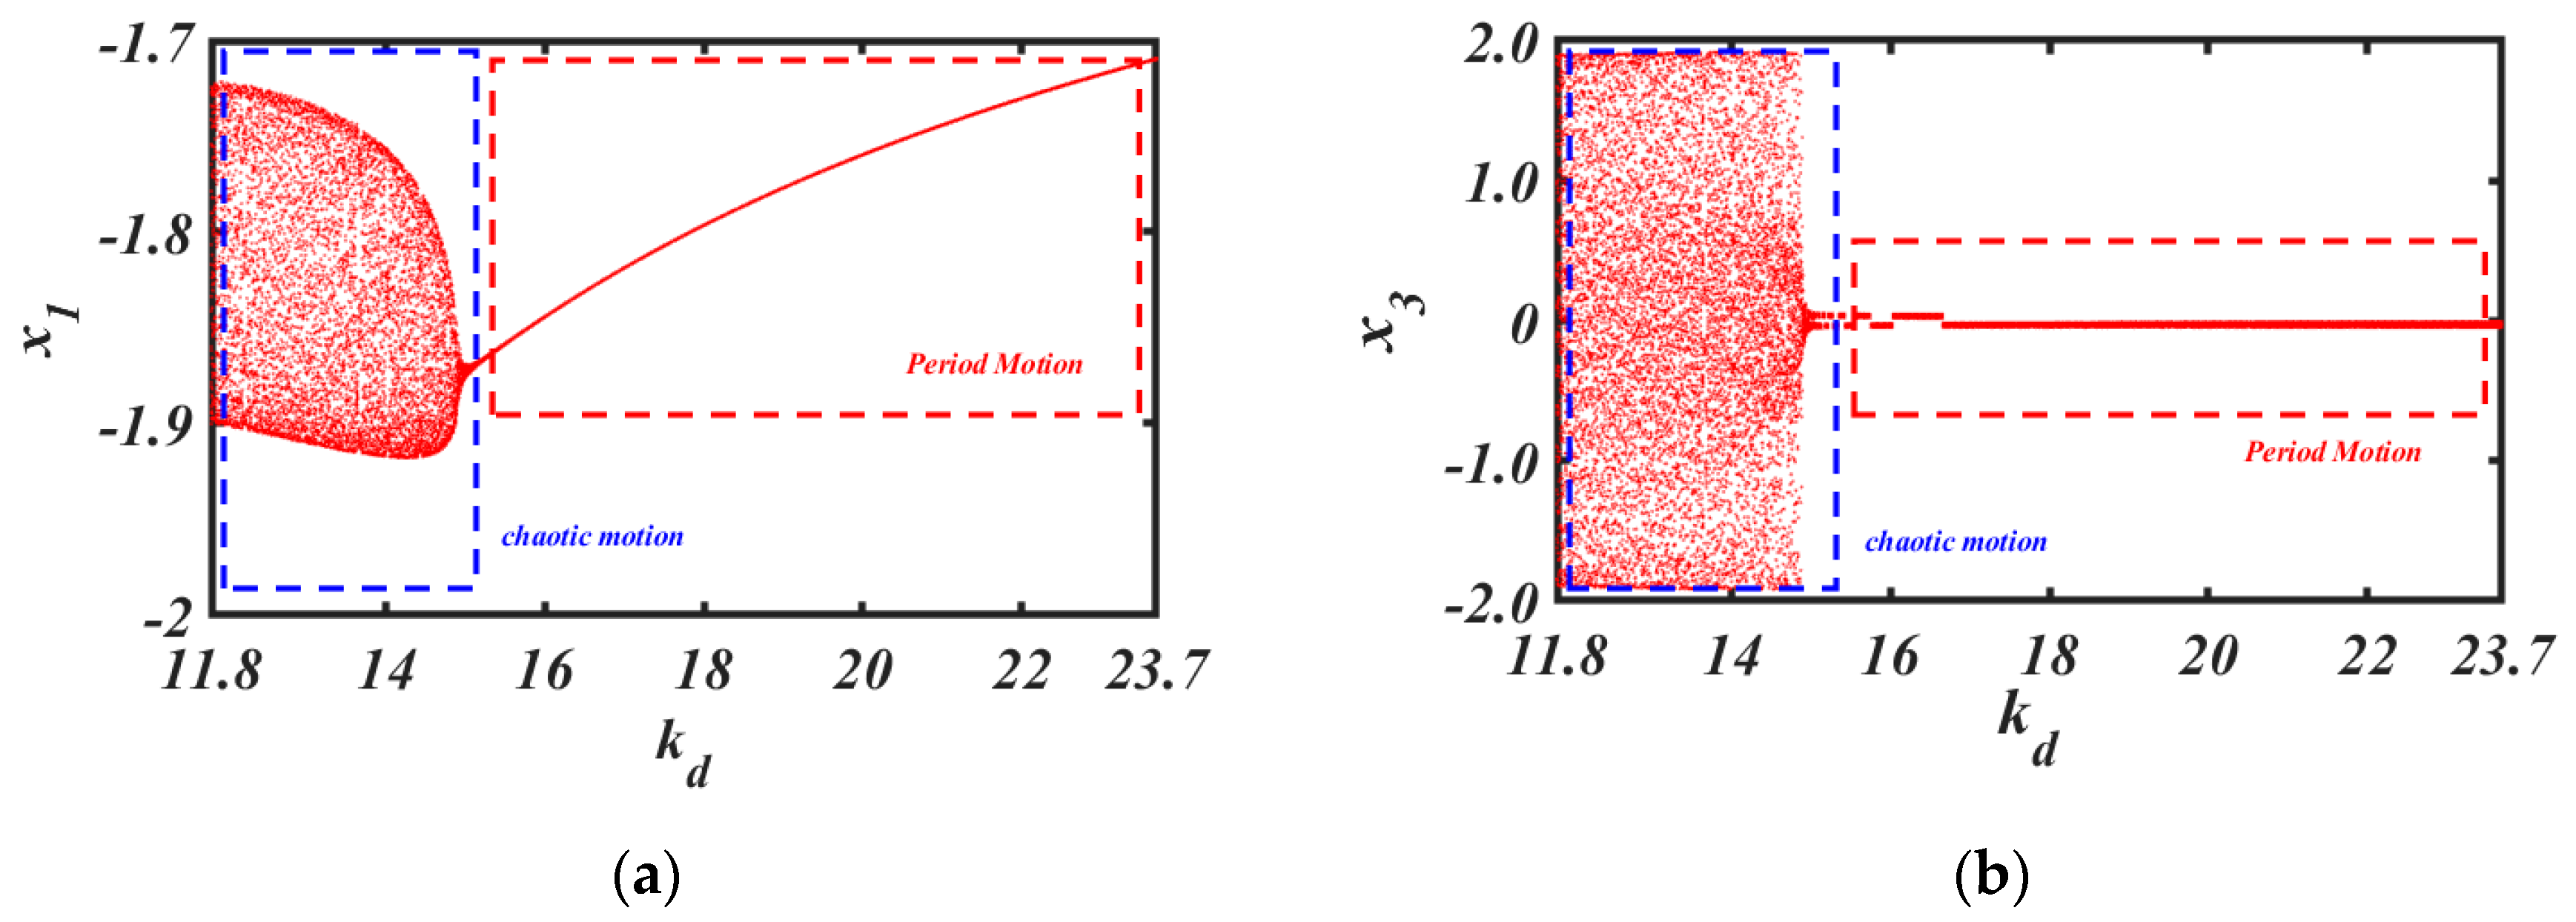
In Figure 12a,b, the horizontal axis represents the variation in the PD control parameter , and the vertical axis represents the displacement of the system’s first-order mode and second-order mode, respectively. From Figure 12a, it can be observed that as the control parameter increases, the system’s first-order mode transitions from chaotic motion to periodic motion. From Figure 12b, it can be seen that as the control parameter increases, the system’s second-order mode exhibits chaotic motion followed by period-doubling motion. Next, based on the different values of in Figure 12, we will further analyze the complex vibration behavior of the 12-pole rotor–AMB system.
Figure 12.
Bifurcation diagrams with varying proportional coefficient : (a) under the first-order mode, (b) under the second-order mode.
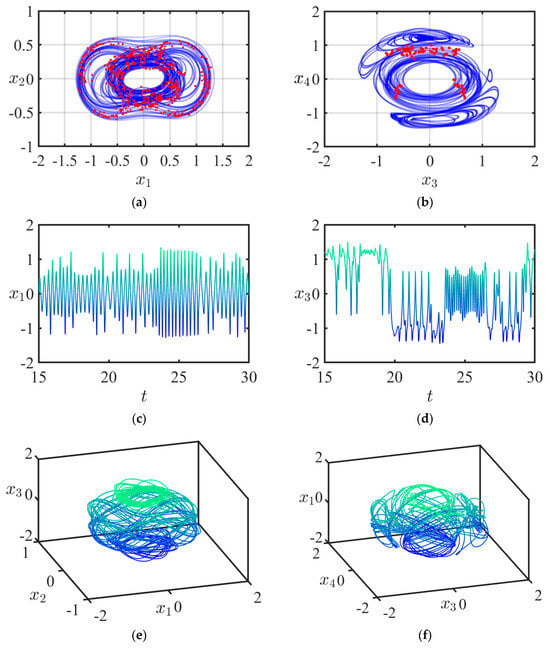
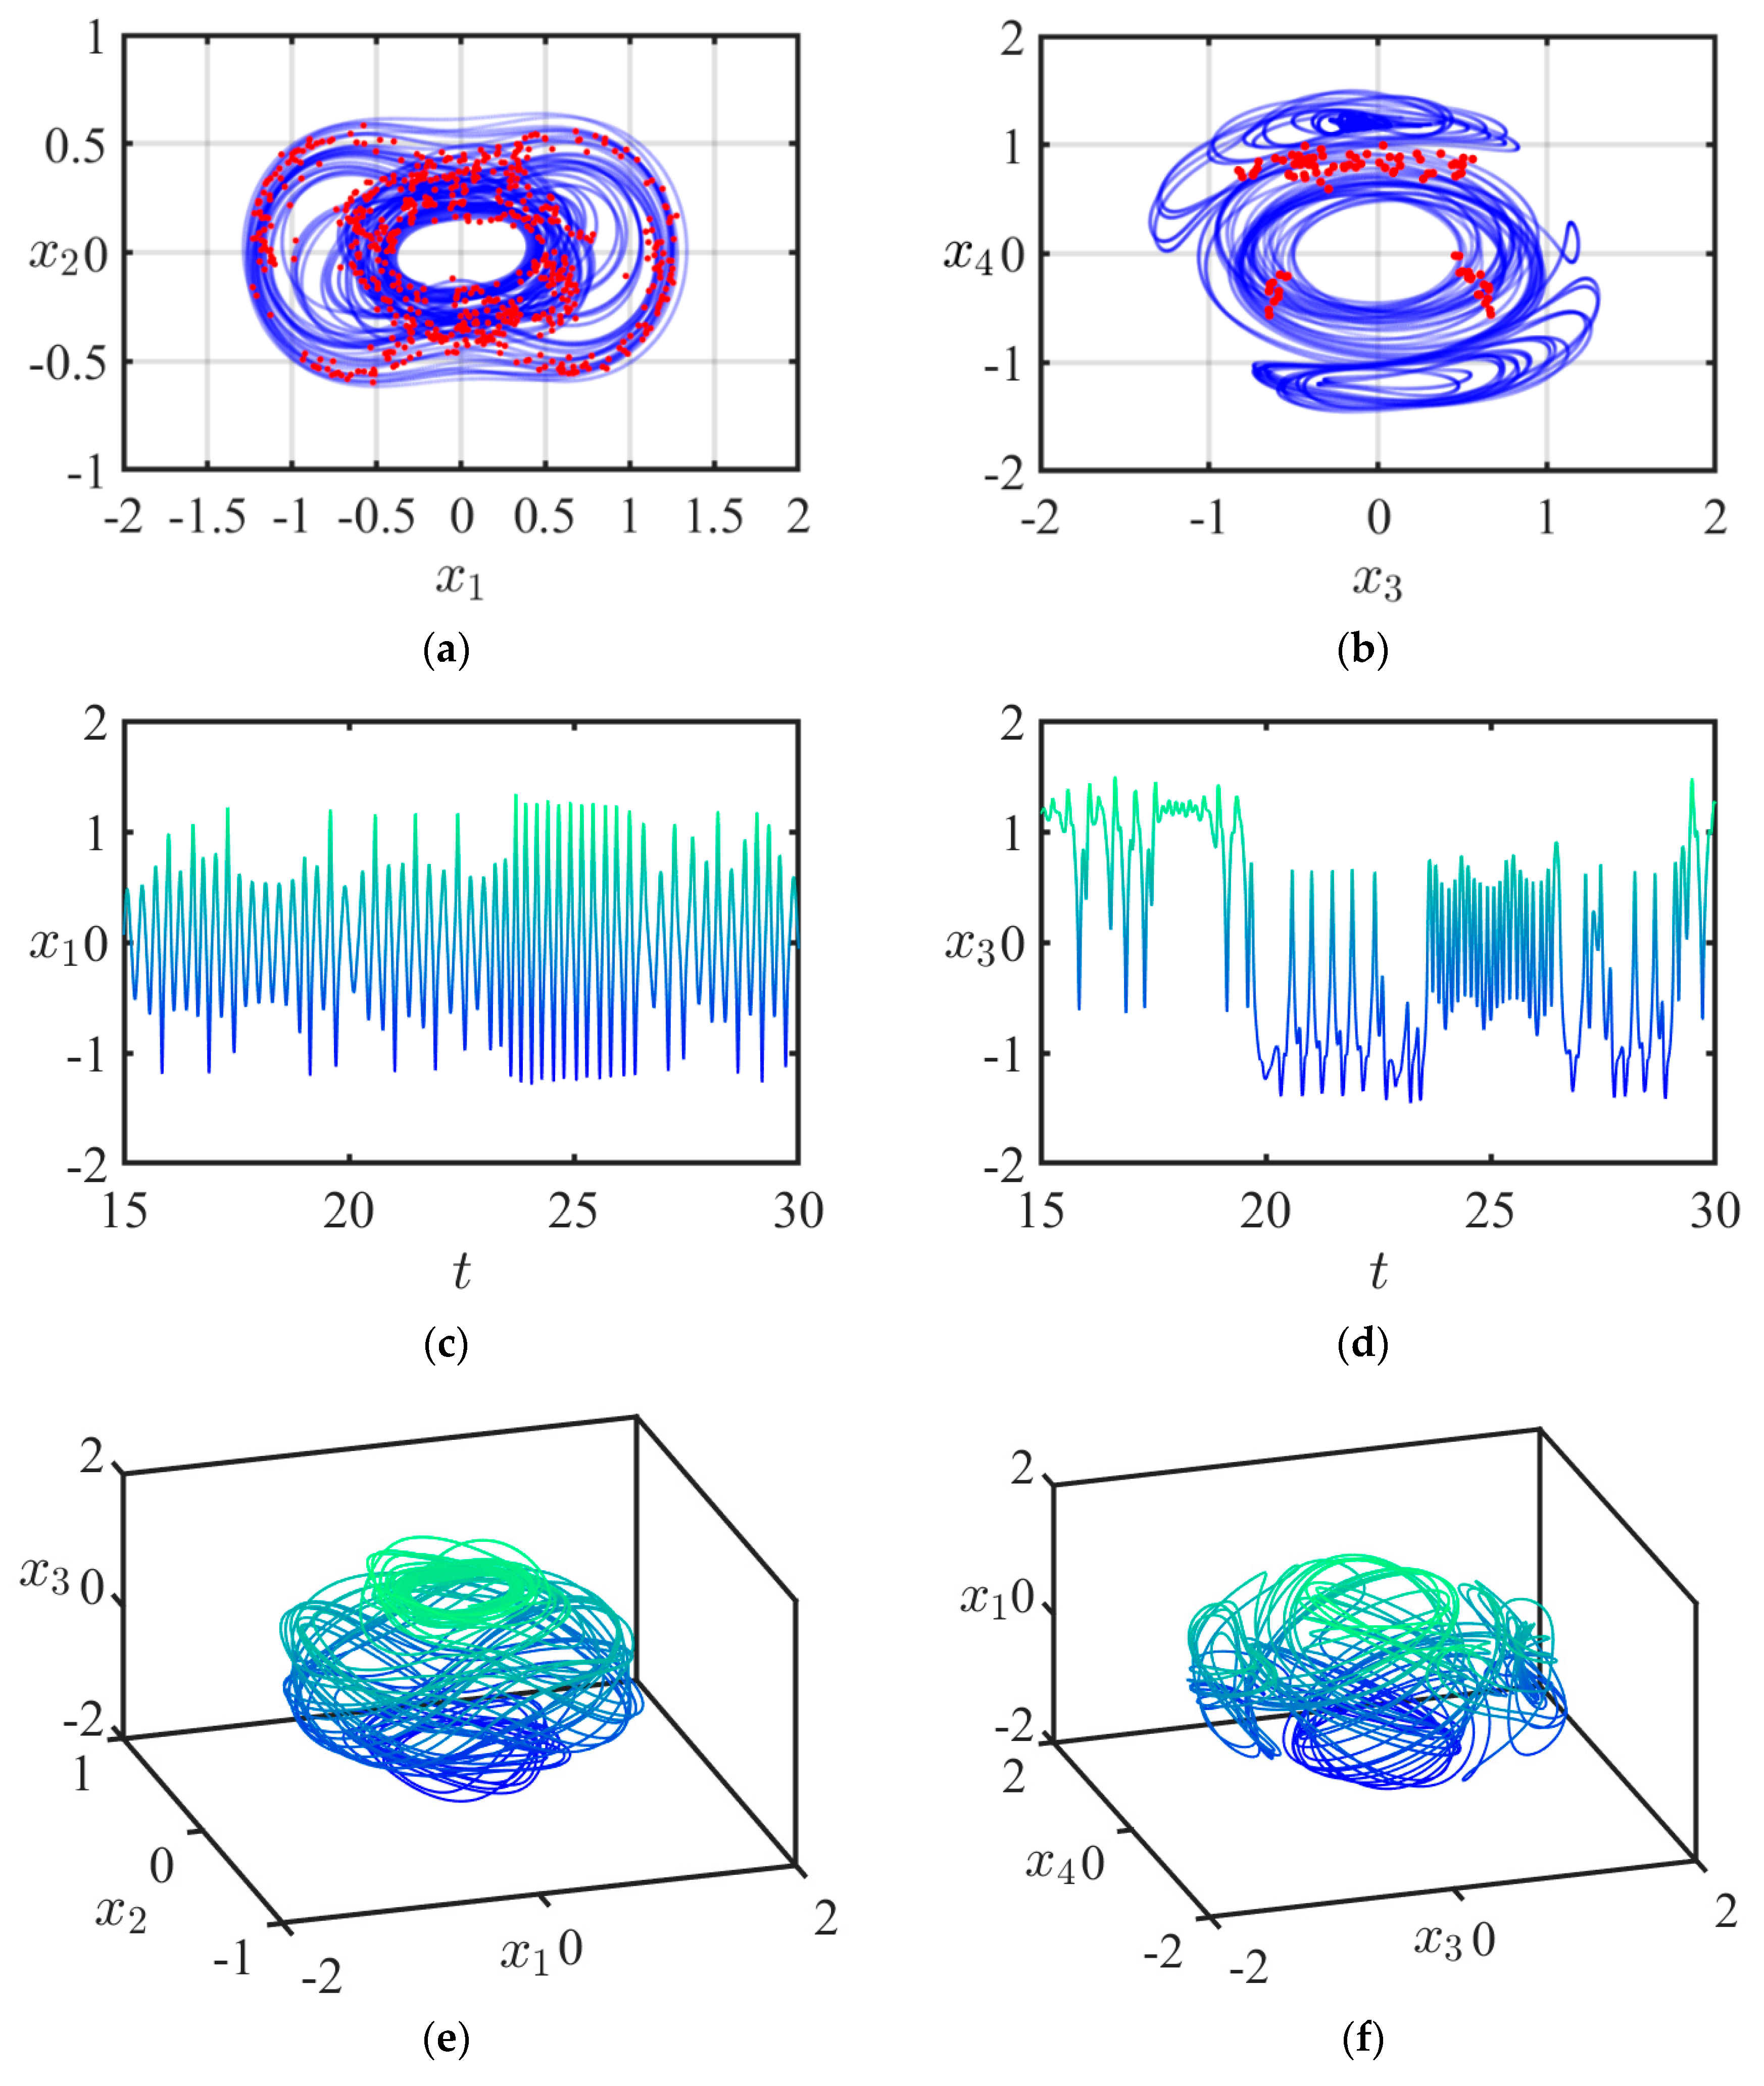
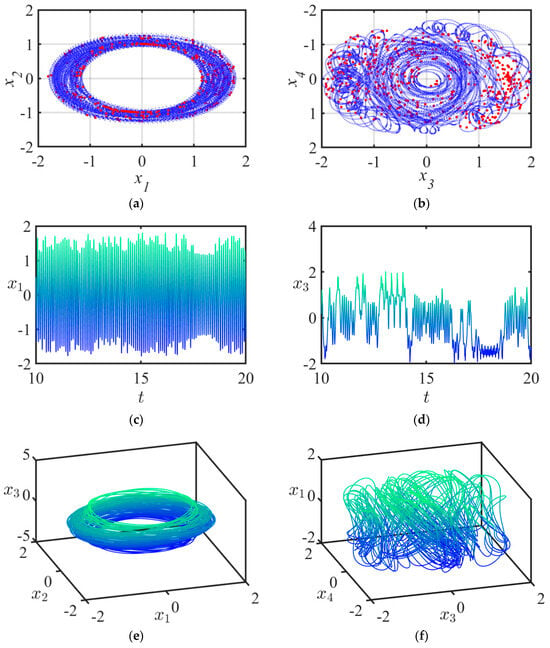
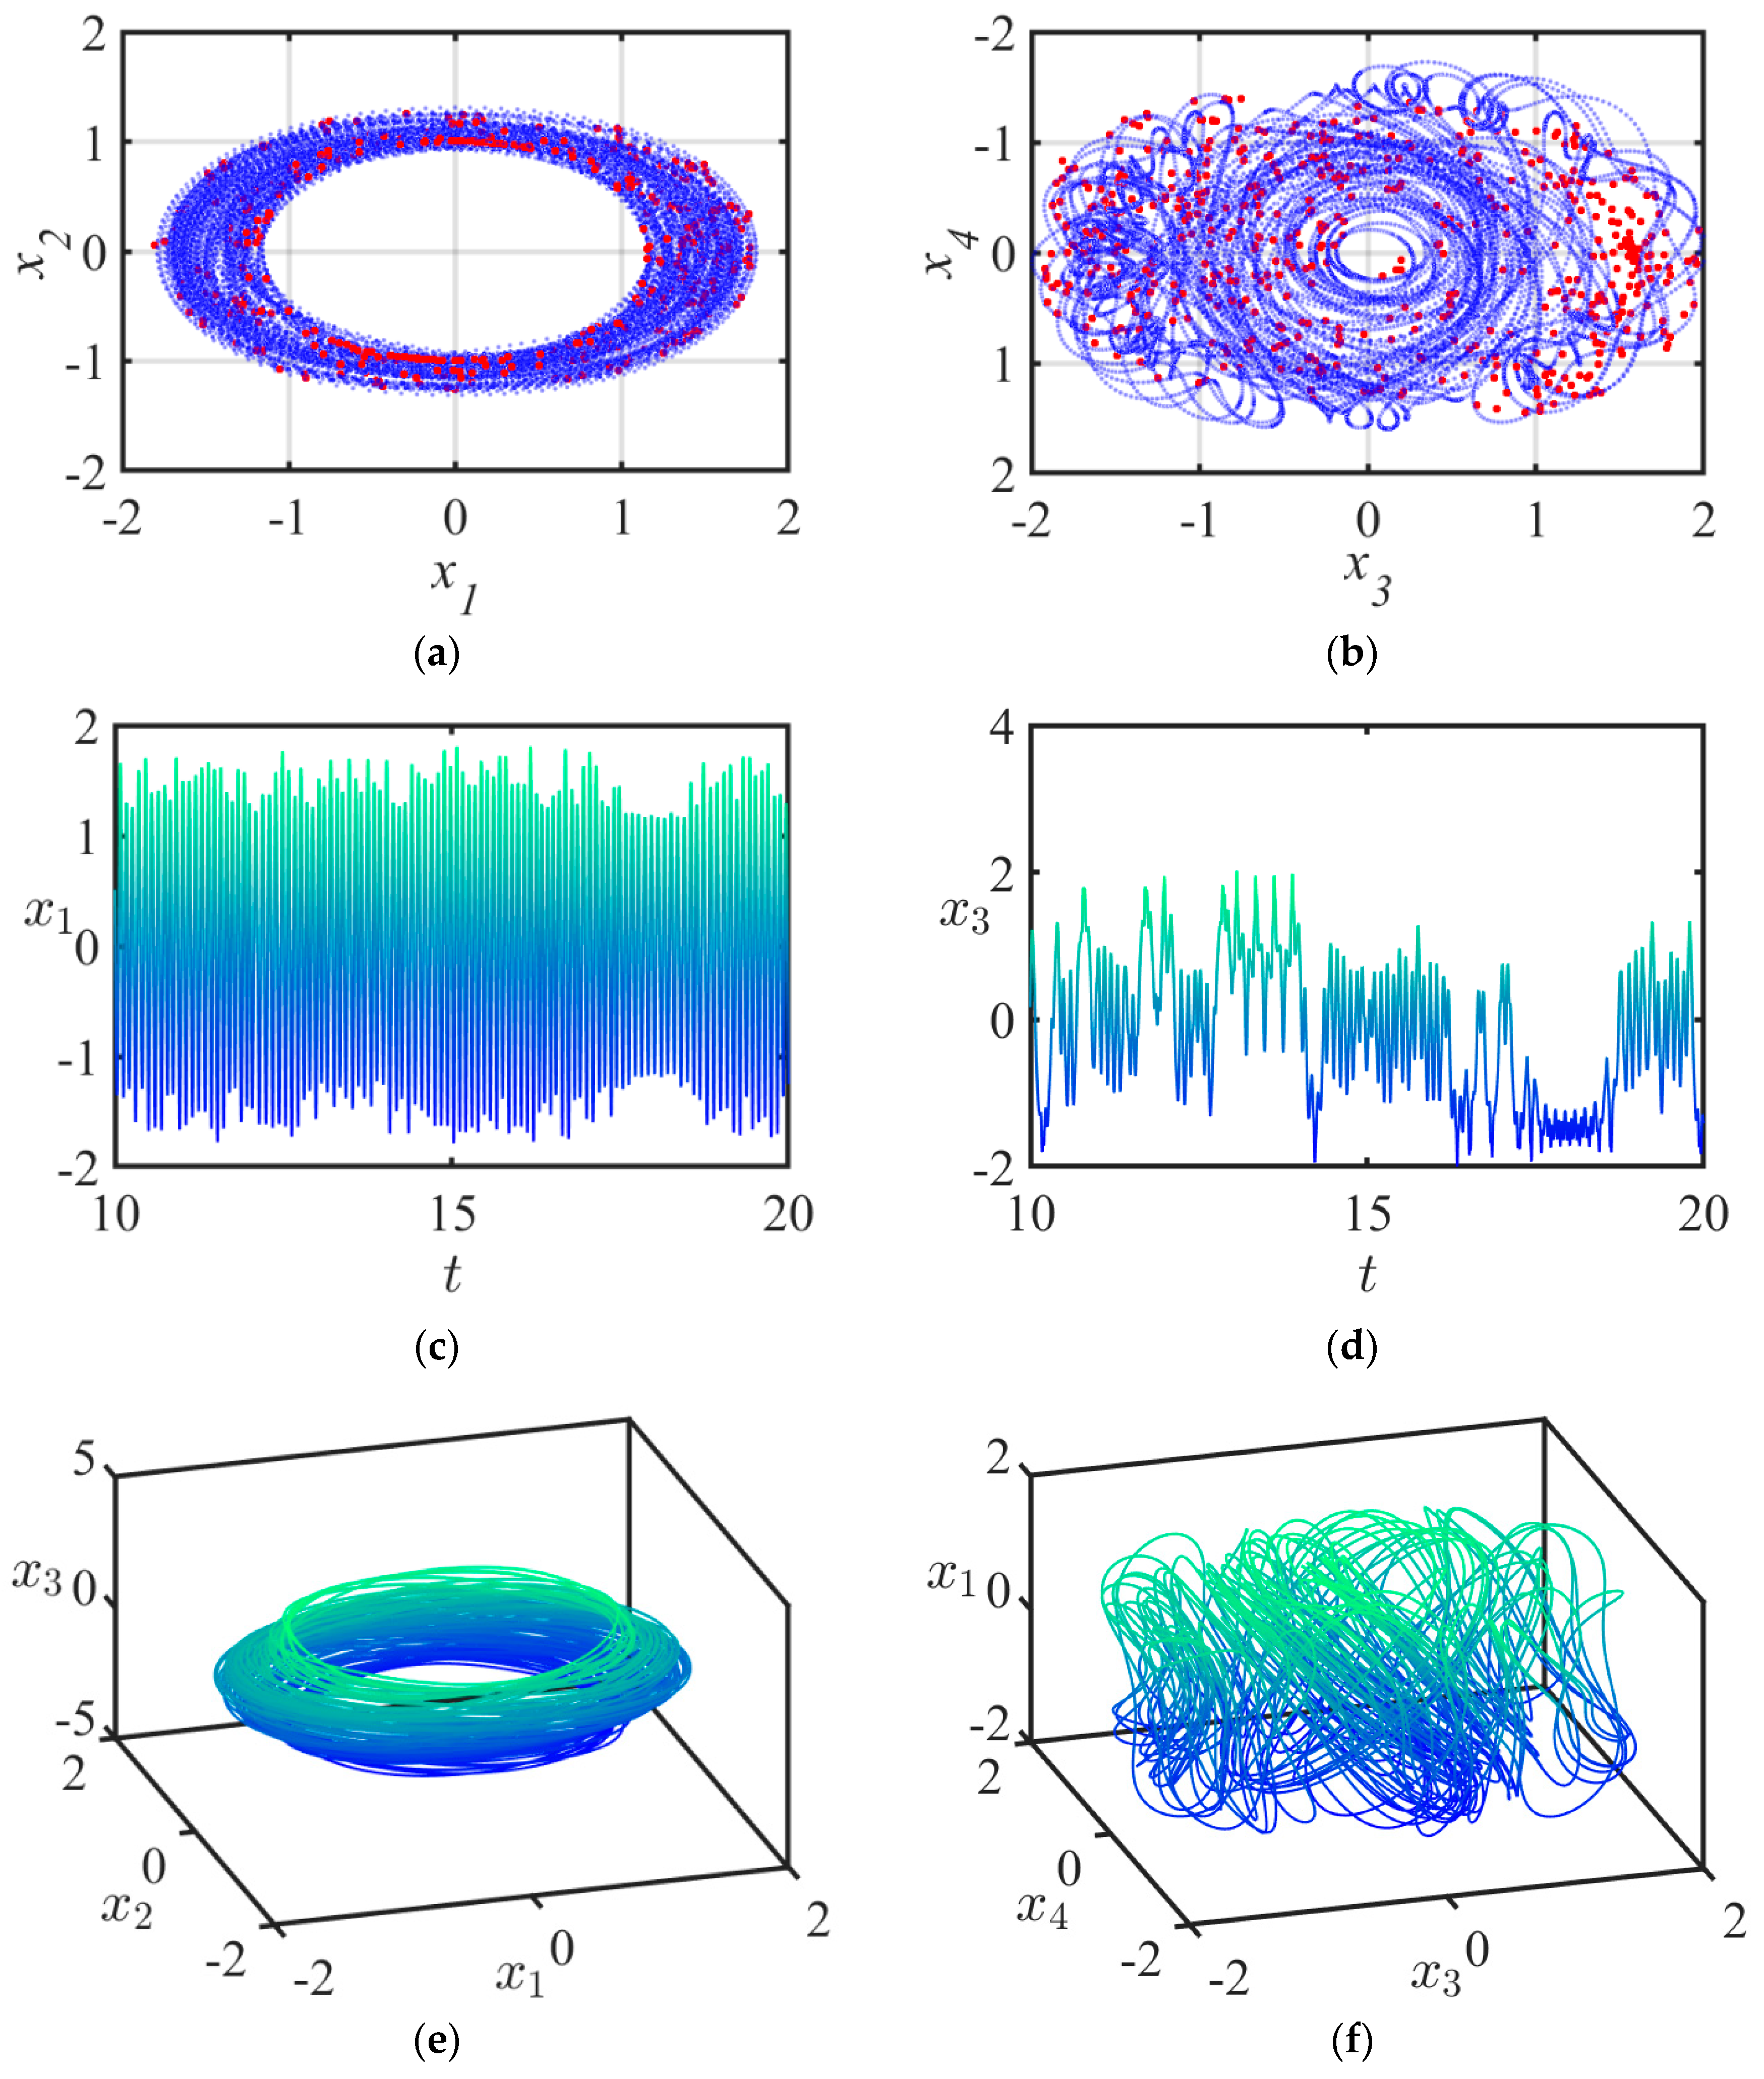
Figure 13 shows that when , the 12-pole rotor–active magnetic bearing (AMB) system exhibits chaotic motion. Figure 13a–f display the phase diagrams and Poincaré maps on the planes and , the time histories on the planes and , and the three-dimensional phase diagrams on the planes and , respectively. The Poincaré map is represented in the same coordinate system as the phase diagram. In the case of periodic motion, the Poincaré map is represented by a red single point (or multiple points), whereas for chaotic motion, it appears as a cluster of red points. From Figure 13a,b, it can be seen that there are two chaotic attractors in the first-order and second-order modes of the system, and these attractors are located on either side of the equilibrium point.
Figure 13.
The presence of chaotic motion when : (a) phase diagram (blue lines) and Poincaré map (red points) on the planes , (b) phase diagram (blue lines) and Poincaré map (red points) on the planes , (c) waveform on the plane , (d) waveform on the plane , (e) phase diagram in three-dimensional coordinates , (f) phase diagram on the plane .
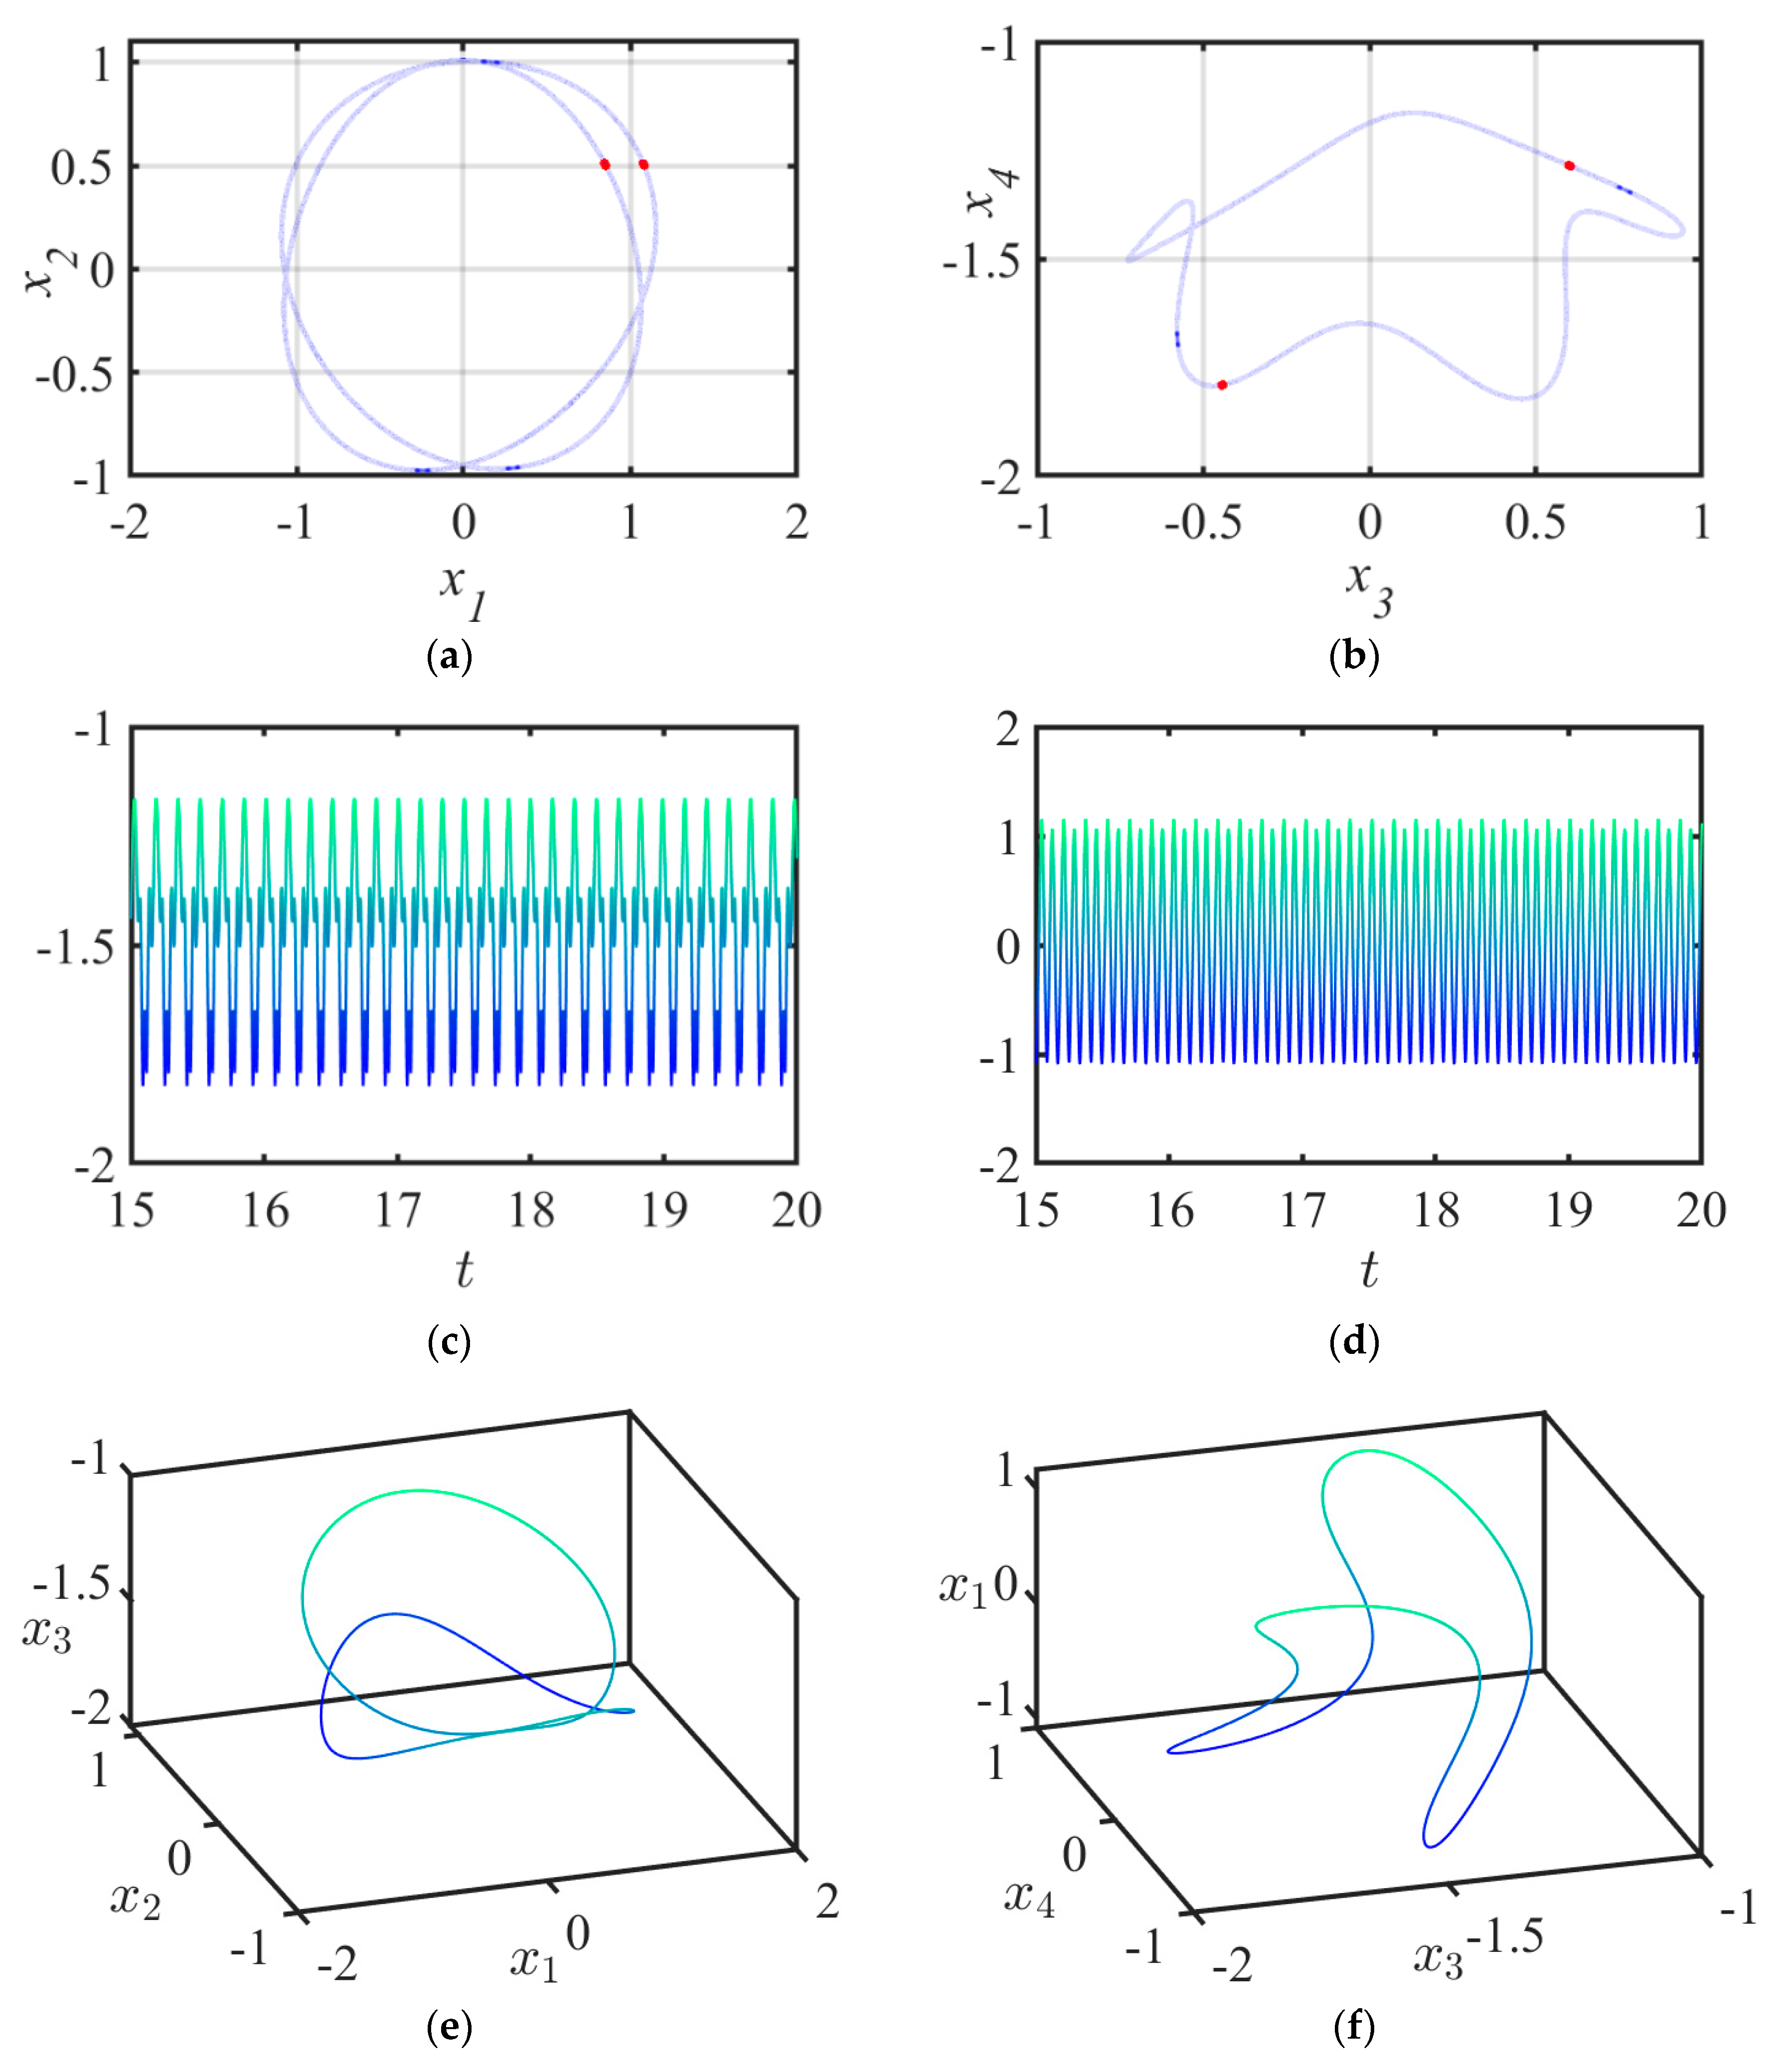
Figure 14 shows that when , from Figure 14a,c, it can be seen that both the first-order mode and the second-order mode of the system exhibit period-doubling motion.
Figure 14.
The presence of periodic motion when : (a) phase diagram (blue lines) and Poincaré map (red points) on the planes , (b) phase diagram (blue lines) and Poincaré map (red points) on the planes , (c) waveform on the plane , (d) waveform on the plane , (e) phase diagram in three-dimensional coordinates , (f) phase diagram on the plane .
From Figure 13 and Figure 14, it can be observed that as the PD control parameter increases, the 12-pole rotor–active magnetic bearing system undergoes a transition from chaotic motion to period-doubling motion. This change indicates that the proportional coefficient has a significant impact on the system’s stability, as it can effectively suppress system vibrations and thus improve stability. However, from the bifurcation diagram in Figure 12, it can be seen that the increase in the differential gain appears to be very small, but the rate of change in the system is very rapid. This also highlights the sensitivity of the differential gain , corresponding to the results of the previous study. Next, we set , and we let be the variable to study the influence of the differential gain on the system’s dynamic behavior.
In Figure 15a,b, the horizontal axis represents the variation in the PD control parameter , and the vertical axis represents the displacement of the system’s first-order mode and second-order mode, respectively. From Figure 15a, it can be observed that as the control parameter increases, both the first-order and second-order modes of the system transition from chaotic motion to periodic motion. Next, we will further analyze the different values of based on Figure 15.
Figure 15.
Bifurcation diagrams with varying differential gain : (a) under the first-order mode, (b) under the second-order mode.
Figure 16 shows that when , the 12-pole rotor–active magnetic bearing (AMB) system exhibits chaotic motion. Figure 16a–f display the Poincaré maps on the planes and , the time histories on the planes and , and the three-dimensional phase diagrams on the planes and , respectively. From Figure 16a, it can be seen that the first-order mode of the system primarily oscillates around the equilibrium point. From Figure 16b, it can be seen that there are two chaotic attractors in the system’s second-order mode, located on either side of the equilibrium point.
Figure 16.
The presence of chaotic motion when : (a) phase diagram (blue lines) and Poincaré map (red points) on the planes , (b) phase diagram (blue lines) and Poincaré map (red points) on the planes , (c) waveform on the plane , (d) waveform on the plane , (e) phase diagram in three-dimensional coordinates , (f) phase diagram on the plane .
Figure 17 shows that when , from Figure 17a,c, it can be seen that both the first-order mode and the second-order mode of the system exhibit periodic motion.
Figure 17.
The presence of chaotic motion when : (a) phase diagram (blue line) and Poincaré map (red point) on the planes , (b) phase diagram (blue line) and Poincaré map (red point) on the planes , (c) waveform on the plane , (d) waveform on the plane , (e) phase diagram in three-dimensional coordinates , (f) phase diagram on the plane .
From Figure 16 and Figure 17, it can be observed that as the PD control parameter increases, the 12-pole rotor–active magnetic bearing system transitions from chaotic motion to period-doubling motion. This change indicates that the differential gain has a significant impact on the system’s stability. Moreover, Figure 15 shows that the range of change for the differential gain is quite large, providing more controllability and adjustability to the system’s stability.
5. Conclusions
This paper investigated the influence of PD control on the vibration characteristics of a 12-pole rotor–AMB system that considers gravity. By conducting numerical simulations of the averaged equations in both polar and Cartesian coordinate systems, various diagrams and plots were obtained, including magnitude-frequency response curves, amplitude and rotor trajectory diagrams, plots of the energy ratio versus the amplitude, bifurcation diagrams, phase portraits, time histories maps, and Poincaré sections. A comprehensive analysis was then performed to examine the effects of the PD controller on the vibration characteristics of the bearing system. The research findings indicate that the PD control parameters have a significant impact on suppressing the system’s vibrations. The main conclusions are as follows:
- The control parameters of the PD controller significantly alter the system’s amplitude, resonance region, and stiffness characteristics. Increasing the controller parameters within a certain range enhances the hardening spring properties of the system, thereby improving the control efficiency, as shown in Figure 2, Figure 3, Figure 4, Figure 5 and Figure 6.
- As shown in Figure 7, Figure 8, Figure 9, Figure 10 and Figure 11, compared to merely increasing the damping coefficient, the PD controller more effectively suppresses the rotor vibrations under no-damping conditions, ensuring motion stability and accelerating energy decay to achieve stable and rapid vibration suppression.
- As shown in Figure 12 and Figure 15, the system can transition from chaotic motion to periodic motion under the adjustment of the proportional coefficient and differential gain , indicating that the PD controller has a significant impact on the system’s stability. The range of the controller parameter changes in the two figures indicates that the proportional coefficient can quickly suppress the system’s vibration, while the differential gain can improve the control effectiveness. This phenomenon is crucial for understanding the dynamic characteristics of magnetic bearing systems and provides an important reference for designing and implementing more effective control strategies.
Author Contributions
Methodology, Y.R. and W.M.; validation, Y.R. and W.M.; investigation, Y.R. and W.M.; data curation, Y.R. and W.M.; writing—original draft preparation, Y.R. and W.M.; writing—review and editing, W.M.; supervision, W.M. All authors have read and agreed to the published version of the manuscript.
Funding
The authors sincerely acknowledge financial support from the National Natural Science Foundation of China (Nos. 12102207, 12272189), the Natural Science Foundation of Inner Mongolia (Nos. 2023JQ14, 2023MS01014), and the 2023 Student Innovation and Entrepreneurship Training Program of Inner Mongolia University of Technology (2023093003).
Data Availability Statement
The data presented in this study can be available from the corresponding authors.
Conflicts of Interest
The authors declare that there are no conflicts of interests regarding the publication of this paper.
References
- Huang, Z.; Li, C.; Zhou, Z.; Liu, B.; Zhang, Y.; Yang, M.; Gao, T.; Liu, M.; Zhang, N.; Sharma, S.; et al. Magnetic bearing: Structure; model; control strategy. Int. J. Adv. Manuf. Technol. 2024, 131, 3287–3333. [Google Scholar] [CrossRef] [Scilit]
- Ji, J.C.; Hansen, C.H. Non-linear oscillations of a rotor in active magnetic bearings. J. Sound Vib. 2001, 240, 599–612. [Google Scholar] [CrossRef] [Scilit]
- Amer, Y.A.; Hegazy, U.H. Resonance behavior of a rotor-active magnetic bearing with time-varying stiffness. Chaos Solitons Fractals 2007, 34, 1328–1345. [Google Scholar] [CrossRef] [Scilit]
- Inayat-Hussain, J.I. Geometric coupling effects on the bifurcations of a flexible rotor response in active magnetic bearings. Chaos Solitons Fractals 2009, 41, 2664–2671. [Google Scholar] [CrossRef] [Scilit]
- Eissa, M.; Kamel, M.; Bauomy, H.S. Dynamics of an AMB-rotor with time varying stiffness and mixed excitations. Meccanica 2012, 47, 585–601. [Google Scholar] [CrossRef] [Scilit]
- Luo, H.Y.; Wang, Y.F. Nonlinear vibration of a continuum rotor with transverse electromagnetic and bearing excitations. Shock Vib. 2012, 19, 1297–1314. [Google Scholar] [CrossRef]
- Saeed, N.A.; Eissa, M.; El-Ganini, W.A. Nonlinear oscillations of rotor active magnetic bearings system. Nonlinear Dyn. 2013, 74, 1–20. [Google Scholar] [CrossRef] [Scilit]
- Zhang, W.; Wu, R.Q.; Siriguleng, B. Nonlinear vibrations of a rotor-active magnetic bearings system with 16-pole legs and two degrees of freedom. Shock Vib. 2020, 10, 1–29. [Google Scholar] [CrossRef] [Scilit]
- Wu, R.Q.; Zhang, W.; Yao, M.H. Nonlinear dynamics near resonances of a rotor-active magnetic bearings system with 16-pole legs and time varying stiffness. Mech. Syst. Signal Process. 2018, 100, 113–134. [Google Scholar] [CrossRef] [Scilit]
- Saeed, N.A.; El-Shourbagy, S.M.; Kamel, M.; Raslan, K.R.; Aboudaif, M.K. Nonlinear dynamics and static bifurcations control of the 12-pole magnetic bearings system utilizing the integral resonant control strategy. J. Low Freq. Noise Vib. Act. Control 2022, 41, 1532–1560. [Google Scholar] [CrossRef] [Scilit]
- Ji, J.C.; Leung, A.Y.T. Non-linear oscillations of a rotor-magnetic bearing system under superharmonic resonance conditions. Int. J. Non-Linear Mech. 2003, 38, 829–835. [Google Scholar] [CrossRef] [Scilit]
- Kamel, M.; Bauomy, H.S. Nonlinear behavior of a rotor-AMB system under multi-parametric excitations. Meccanica 2009, 45, 7–22. [Google Scholar] [CrossRef] [Scilit]
- Inoue, T.; Sugawara, Y. Nonlinear vibration analysis of a rigid rotating shaft supported by the magnetic bearing (influence of the integral feedback in the PID control of the vertical shaft). J. Syst. Des. Dyn. 2010, 4, 471–483. [Google Scholar] [CrossRef] [Scilit]
- Sung, H.C.; Park, J.B.; Joo, Y.H. Robust Fuzzy Controller for Active Magnetic Bearing System with 6-DOF. J. Korean Inst. Intell. Syst. 2012, 22, 267–272. [Google Scholar]
- Zhang, G.; Xi, G. Vibration control of a time-delayed rotor-active magnetic bearing system by time-varying stiffness. Int. J. Appl. Mech. 2022, 14, 2250007. [Google Scholar] [CrossRef] [Scilit]
- Wu, H.C.; Zhang, L.; Zhou, J.; Hu, Y.F. Dynamic analysis and vibration control of a rotor-active magnetic bearings system with base motion. J. Vib. Control 2023, 30, 2697–2708. [Google Scholar] [CrossRef] [Scilit]
- Xu, X.; Liu, Y.; Han, Q. A universal dynamic model and solution scheme for the electrical rotor system with wide range of eccentricity. Int. J. Non-Linear Mech. 2023, 152, 104402. [Google Scholar] [CrossRef] [Scilit]
- Chang, C.W.; Chu, L.M.; Chen, T.C.; Yau, H.T. Nonlinear dynamic of turbulent bearing-rotor system under quadratic damping with HSFD and active control. J. Braz. Soc. Mech. Sci. Eng. 2024, 26, 123. [Google Scholar] [CrossRef] [Scilit]
- Wang, C.; Liu, C.C.; Cao, S.K.; Sun, L. Nonlinear vibration control of magnetic bearing system considering positive and negative stiffness. J. Vib. Control 2024, 1–11. [Google Scholar] [CrossRef] [Scilit]
- Yeh, T.; Chung, Y.; Wu, W. Sliding Control of Magnetic Bearing Systems. J. Dyn. Syst. Meas. Control 2001, 123, 353–362. [Google Scholar] [CrossRef] [Scilit]
- Kaya, I. A PI-PD controller design for control of unstable and integrating processes. Isa Trans. 2003, 42, 111–121. [Google Scholar] [CrossRef] [Scilit]
- Jawaid, I.I.H. Bifurcations in the response of a rigid rotor supported by load sharing between magnetic and auxiliary bearings. Meccanica 2011, 46, 1341–1351. [Google Scholar]
- Wu, R.Q.; Yao, M.H. Analysis of Nonlinear Dynamics of a Rotor-Active Magnetic Bearing System with 16-Pole Legs. In Proceedings of the ASME 2017 International Design Engineering Technical Conferences and Computers and Information in Engineering Conference, Cleveland, OH, USA, 6–9 August 2017; Volume 6, p. 8. [Google Scholar]
- Ghazavi, M.R.; Sun, Q. Bifurcation onset delay in magnetic bearing systems by time varying stiffness. Mech. Syst. Signal Process. 2017, 90, 97–109. [Google Scholar] [CrossRef] [Scilit]
- Saeed, N.A.; Kandil, A. Two different control strategies for 16-pole rotor active magnetic bearings system with constant stiffness coefficients. Appl. Math. Model. 2021, 92, 1–22. [Google Scholar] [CrossRef] [Scilit]
- Ma, W.S.; Zhang, W.; Zhang, Y.F. Stability and multi-pulse jumping chaotic vibrations of a rotor-active magnetic bearing system with 16-pole legs under mechanical-electric-electromagnetic excitations. Eur. J. Mech.-A/Solids 2021, 85, 104120. [Google Scholar] [CrossRef] [Scilit]
- Kandil, A.; Sayed, M.; Saeed, N.A. On the nonlinear dynamics of constant stiffness coefficients 16-pole rotor active magnetic bearings system. Eur. J. Mech.-A/Solids 2020, 84, 104051. [Google Scholar] [CrossRef] [Scilit]
- Saeed, N.A.; Awwad, E.M.; El-Meligy, M.A.; Nasr, E.S.A. Radial versus cartesian control strategies to stabilize the nonlinear whirling motion of the six-pole rotor-AMBs. IEEE Access. 2020, 8, 138859–138883. [Google Scholar] [CrossRef] [Scilit]
- Xu, B.Y.; Zhou, J.; Xu, L.X. Adaptive backstepping control of active magnetic bearings with slice rotor. J. Vib. Eng. Technol. 2022, 10, 795–808. [Google Scholar] [CrossRef] [Scilit]
- Wei, S.; Zhou, J.; Han, X.; Zheng, S. A simplified analysis method and suppression of the modalities of a magnetic levitation turbo rotor system. Vacuum 2023, 217, 112452. [Google Scholar] [CrossRef] [Scilit]
- Zhou, Y.; Zhou, J.; Wang, Y.; Zhang, Y.; Xu, Y. Optimal phase compensation for a rotor-AMB system considering interface contact. J. Vib. Control 2023, 30, 2059–2071. [Google Scholar] [CrossRef] [Scilit]
- Kandil, A.; Hou, L.; Sharaf, M.; Arafa, A.A. Configuration angle effect on the control process of an oscillatory rotor in 8-pole active magnetic bearings. Mathematics 2024, 9, 12928–12963. [Google Scholar] [CrossRef] [Scilit]
- El-Shourbagy, S.M.; Saeed, N.A.; Kamel, M.; Raslan, K.R.; Aboudaif, M.K.; Awrejcewicz, J. Control performance, Stability conditions, and bifurcation analysis of the twelve-pole active magnetic bearings system. Appl. Sci. 2021, 11, 10839. [Google Scholar] [CrossRef] [Scilit]
- Nayfeh, A.H. Resolving Controversies in the Application of the Method of Multiple Scales and the Generalized Method of Averaging. Nonlinear Dyn. 2005, 40, 61–102. [Google Scholar] [CrossRef] [Scilit]
- Butcher, J.C. Runge–Kutta Methods for Ordinary Differential Equations. In Numerical Analysis and Optimization; Al-Baali, M., Grandinetti, L., Purnama, A., Eds.; Springer Proceedings in Mathematics & Statistics; Springer: Berlin/Heidelberg, Germany, 2015; Volume 34, pp. 37–58. [Google Scholar]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).