


Abstract
In contemporary manned–unmanned teaming (MUM-T) systems, the accurate detection of aircraft in Synthetic Aperture Radar (SAR) imagery is crucial for battlefield surveillance and target identification. However, challenges such as background clutter, significant scale variations, and limitations in existing feature extraction methods hinder detection accuracy. To address these issues, this study proposes CCS-Net, a lightweight Cooperative Context-aware Sensing Network designed specifically for SAR aircraft detection. CCS-Net enhances image contrast through Contrast-Limited Adaptive Histogram Equalization (CLAHE) preprocessing and employs a novel C2F_LK module combined with a Multi-scale Context Aggregation (MSCA) module to improve multi-scale feature representation with minimal parameters. An FPN-PAN structure adaptively fuses these features, while the Spatial Coordinate Attention Head (SCA-Head) integrates spatial and coordinate attention mechanisms to emphasize key aircraft regions. Optimized with label smoothing, our model achieves a 96.6% mAP@0.5 and 93.5% precision on the SAR-Aircraft-1.0 dataset with only 0.97M parameters. It generalizes well on the SADD aircraft dataset and cross-domain HRSID and SSDD ship benchmarks, outperforming state-of-the-art methods in both accuracy and lightweight design.
1. Introduction
In contemporary manned–unmanned teaming (MUM-T) cooperative engagement systems, unmanned reconnaissance aircraft function as the primary assets for acquiring battlefield situational awareness. Synthetic Aperture Radar (SAR) has become a key payload carried by reconnaissance platforms due to its unique technical advantages [1]. As an active form of microwave imaging radar, SAR overcomes the dependencies of optical imaging technologies on weather and illumination conditions, thereby enabling the efficient acquisition of high-resolution ground target imagery in complex meteorological and all-weather environments. Consequently, it is now widely applied in military reconnaissance, environmental monitoring, emergency disaster response, and other fields, establishing itself as a core technological means for ground target monitoring [2]. SAR images are inherently affected by coherent speckle noise during the imaging process. Furthermore, the multi-scale characteristics of targets and dynamic variations in imaging perspectives often lead to degraded features and reduced discriminability of aircraft in SAR imagery, which poses significant challenges to the design and optimization of detection algorithms [3]. Therefore, conducting research on key technical challenges in aircraft detection from SAR imagery is of significant practical importance in terms of enhancing the operational capabilities of unmanned reconnaissance aircraft and improving the accuracy of target monitoring.
CFAR detection technology is the main method for traditional SAR target detection. It distinguishes targets from backgrounds by adaptively adjusting detection thresholds [4]. Researchers have proposed various methods, such as non-Gaussian CFAR [5], II-CFAR [6], and multiscale CFAR [7]. These approaches improve detection reliability, computational efficiency, and feature preservation. Pioneering machine learning methods like support vector machines [8] and random forests [9] enable basic detection via simple feature extraction. However, traditional methods still require manual analysis against complex backgrounds and face difficult parameter tuning, which limits end-to-end learning. The advent of deep learning has precipitated the gradual mainstreaming of object detection algorithms, with the adoption of convolutional neural network (CNN) object detection algorithms. In contradistinction to conventional methodologies, deep learning algorithms possess the capacity to automatically discern the intricate characteristics of objects from voluminous SAR image data by means of multi-layer neural networks. This obviates the necessity for manual feature design and circumvents the constraints imposed by “experience dependency” [10]. Currently, CNN-based object detection algorithms can be divided into two categories: two-stage methods (R-CNN [11] and Fast R-CNN [12]), which offer high detection accuracy but slower processing speeds, and single-stage methods (SSD [13] and the YOLO series [14]), which balance speed and accuracy, making them more suitable for real-time detection scenarios. The enhancement of model performance is the primary focus of existing research, which is primarily concentrated in three areas: image preprocessing, network architecture optimization, and improvement of loss functions. Moreover, the release of SAR datasets accessible to the public has further accelerated progress in this domain.
To address the requirements for the identification of military aircraft, academic research has been conducted on the optimization of algorithms from a plurality of perspectives. Existing SAR detection methods mainly focus on three research directions: feature enhancement, attention-mechanism embedding, and lightweight network design. Advanced detectors adopt transformer structures, deformable convolution, and multi-branch feature pyramids to improve feature representation for low signal-to-noise ratios and cluttered backgrounds. Meanwhile, lightweight networks and optimized feature fusion architectures have been continuously developed to balance detection accuracy and computational efficiency for real-time reconnaissance tasks. Despite these advancements, most existing methods still suffer from limited multi-scale context perception and insufficient feature discrimination for diverse aircraft targets, leaving room for further performance improvement.
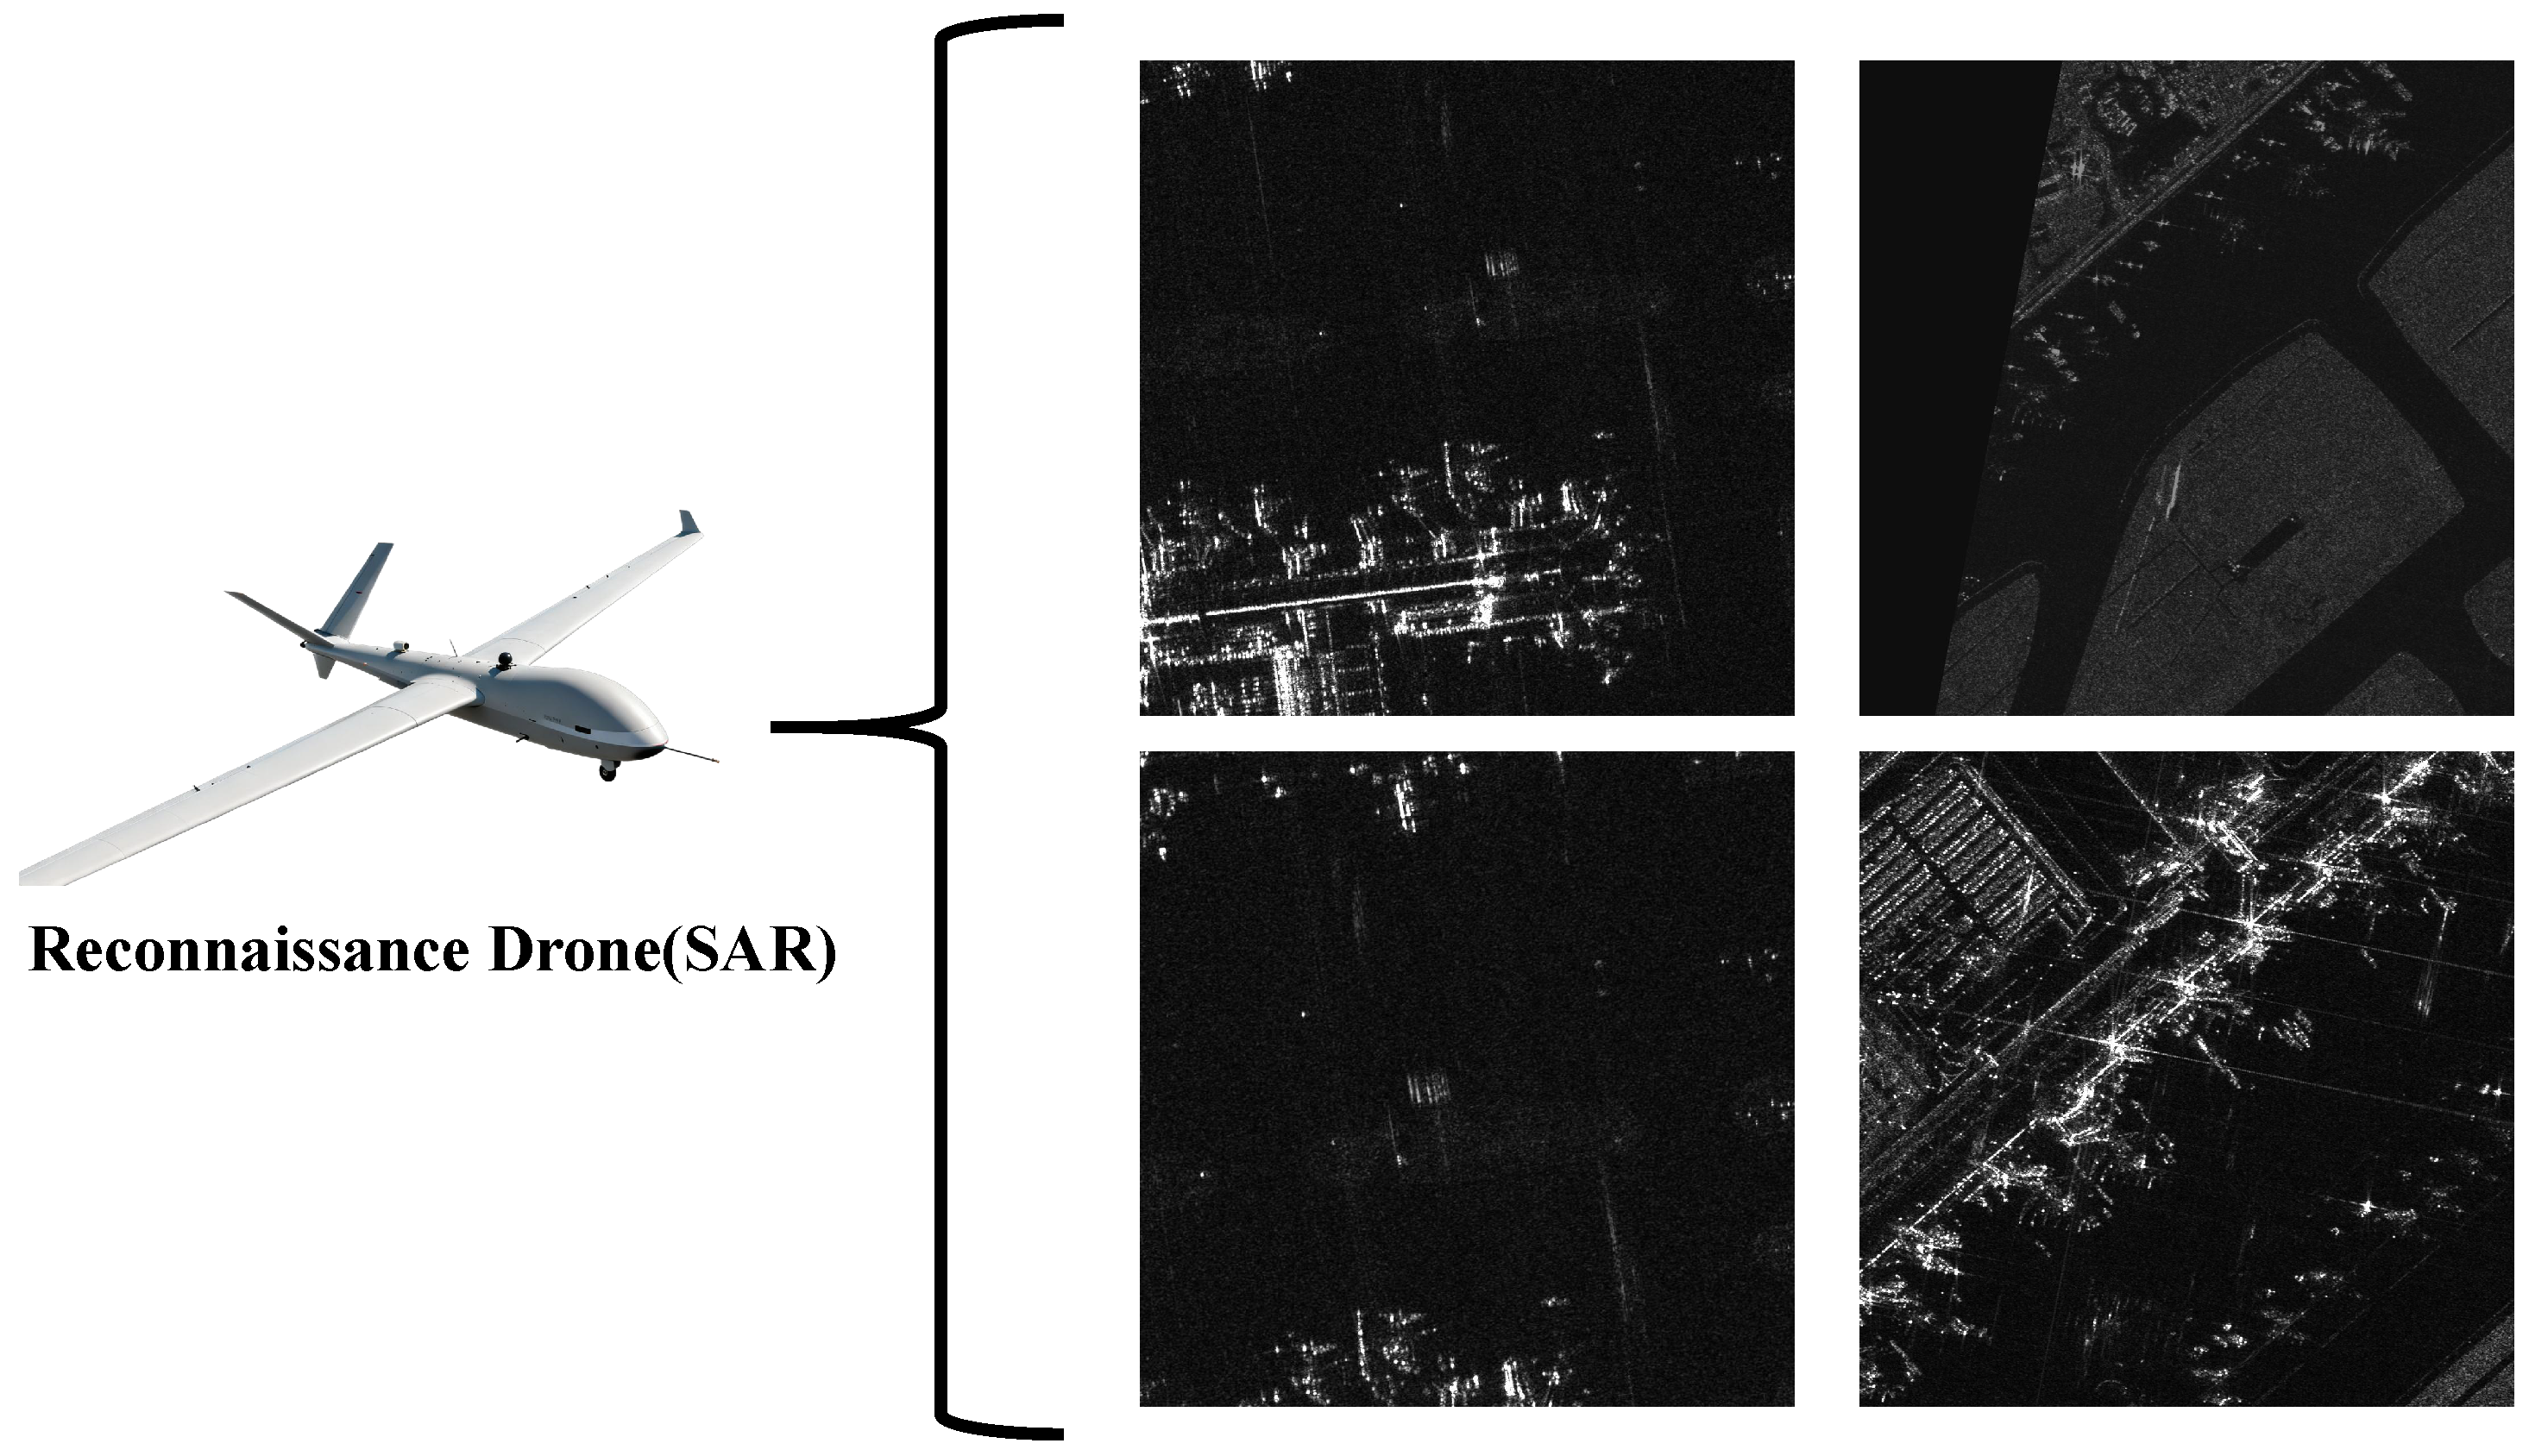
However, existing research methods generally suffer from issues such as complex model structures and heavy computational burdens. Furthermore, as shown in Figure 1, SAR images still present challenges, including background clutter interference, significant variations in target scales, and inconsistent target features caused by changes in imaging geometry. To address these issues, this paper proposes a lightweight detection model named CCS-Net, with the following main contributions:
- A contrast-limited adaptive histogram equalization method is introduced for SAR image preprocessing to enhance image contrast and suppress noise.
- We designed a C2F_LK module and a Multi-scale Context Aggregation (MSCA) module incorporating depthwise separable convolutions and atrous spatial pyramid pooling to enhance multi-scale feature extraction capability.
- A Spatial Coordinate Attention Head (SCA-Head) structure is proposed, which integrates dual spatial and coordinate attention mechanisms to improve perception and localization accuracy for small targets.
- The loss function is optimized by introducing label smoothing to mitigate class imbalance.
Figure 1.
Synthetic Aperture Radar (SAR) image captured by an unmanned reconnaissance drone, where bright highlights and structural patterns indicate the presence and layout of aircraft targets.
The following sections of this paper are organized as follows: “Related Work” reviews the progress in deep learning-based SAR target detection methods. “Methodology” details the overall framework of the proposed CCS-Net model and the design principles of its core modules. “Experiments” describes the experimental dataset, evaluation metrics, and implementation details. “Results and Analysis” provides a systematic comparison between the proposed method and other mainstream approaches, validates the effectiveness of each module through ablation studies, and objectively summarizes the advantages and limitations of the proposed method. Finally, “Conclusions” summarizes the main work and outlines potential directions for future research.
2. Related Work
The field of SAR image interpretation has been significantly advanced by the development of deep learning-based detectors. Existing research optimizes detectors in three key directions: attention enhancement, multi-scale feature fusion, and lightweight design.
2.1. Attention Mechanism-Based Methods
Attention mechanisms boost SAR detection by highlighting target features and filtering clutter, letting networks automatically focus on aircraft-salient areas and raising target-background SNR under speckle noise.
For spatial attention, OE-YOLO [15] embeds coordinate attention into YOLOv7, splitting global pooling into horizontal/vertical 1D encodings to capture long-range spatial relations and separate overlapping aircraft in crowded scenes. Nichol et al. [16] further embed coordinate attention into FPN to build cross-scale position constraints, solving feature distortion induced by aircraft azimuth variation. To suppress clutter, Shao et al. [17] introduce self-attention into the COVAD model, guiding the network to ignore useless background and strengthen feature discrimination for noisy SAR data. Adaptive scale-aware attention is studied in MLSDNet [18], which adopts multi-branch learnable weights to adjust receptive fields dynamically. This lightweight design handles multi-size aircraft and cuts false alarms in coastal SAR scenes. Juan et al. [19] add a lightweight channel attention block to SSD, recalibrating shallow features to improve small aircraft detection. Guo et al. [20] propose the Scatter-Enhanced Attention Pyramid Network, combining SAR physical scattering priors with attention modules to amplify strong scattering aircraft regions in multi-scale pyramids. Zhang et al. [21] couple attention with coherent scatter enhancement for low-SNR aircraft detection and clutter suppression. Beyond detection backbones, Wen et al. [22] design an iterative feature purification framework to eliminate shared feature interference and refine the precision of aircraft localization.
Attention mechanisms address the long-range dependency limitation of conventional sequence models by dynamically weighting different input positions, capturing both local and global contextual information. Motivated by this property, we propose two novel attention-driven modules: C2F_LK and SCA-Head.
2.2. Multi-Scale Feature Fusion Optimization
Feature fusion techniques significantly enhance the detection capability of deep learning models for multi-scale targets in SAR images by effectively integrating feature information from different network levels and scales. These techniques fully leverage the detailed features from shallow networks and semantic features from deep networks, improving classification accuracy while maintaining localization precision. They play a crucial role in addressing detection challenges arising from significant scale variations and complex backgrounds in SAR images.
GEFCSI-Net [23] builds an adaptive, densely connected feature pyramid, which dynamically assigns fusion weights according to input SAR images to maintain semantic consistency across multi-scale targets. Zhang et al. [24] embedded attention blocks and geometric constraints into YOLOv5, improving anti-interference detection performance under complex dynamic scenes.
For regional feature extraction, S-Faster RCNN [25] adds multi-scale pooling branches after RoI pooling. It fuses features of to sizes via concatenation and nonlinear transformation and adopts LeakyReLU to alleviate gradient sparsity for better SAR target feature representation.
As in the classic pyramid framework, RetinaNet [26] constructs FPN on ResNet with top-down and lateral connections, performing multi-level detection from P3 to P7 to boost small-target detection. Xiao et al. [27] designed a peak feature enhancement module to highlight aircraft strong-scattering areas and suppress clutter; combined with deformable convolutions, it improves robustness to target deformation. Wang et al. [28] realized weighted multi-scale fusion, together with spatial attention, adaptively highlighting target-relevant regions to cut computation cost without losing detection precision.
Despite these progressions, most existing fusion structures lack sufficient cross-scale feature alignment for aircraft with huge size differences under SAR speckle noise. To tackle this limitation, our CCS-Net adopts an FPN-FAN multi-scale fusion structure.
2.3. Lightweight SAR Detectors
Lightweight architectures are indispensable for real-time airborne SAR reconnaissance, and representative lightweight optimization schemes include SFS-CNet [29], which constructs a compact dual spatial–frequency branch with fractional Gabor transformers and dynamic receptive fields to extract multi-scale features without redundant convolutions; YOLOX [30], which boosts lightweight inference efficiency via decoupled detection heads and SimOTA dynamic label assignment; and SA-Net [31], which reduces computational overhead and pose-induced localization bias through sparse scattered keypoint prediction for aircraft contour reconstruction. Nevertheless, these methods merely optimize individual modules separately and seldom jointly integrate lightweight compression, anti-clutter feature enhancement, and multi-scale fusion, which motivates the combination of our lightweight C2F_LK backbone with MSCA and SCA-Head to form the CCS-Net detection framework.
In summary, current SAR aircraft detection studies are generally divided into three research branches: attention-mechanism enhancement, multi-scale feature fusion, and lightweight network optimization. Most existing methods only advance a single technical dimension in isolation, while few unified architectures jointly optimize the three core modules to accommodate the complex speckle noise and wide scale variation of aircraft targets inherent to SAR imagery. To address this research limitation, this paper proposes the integrated CCS-Net detection framework.
3. Methodology
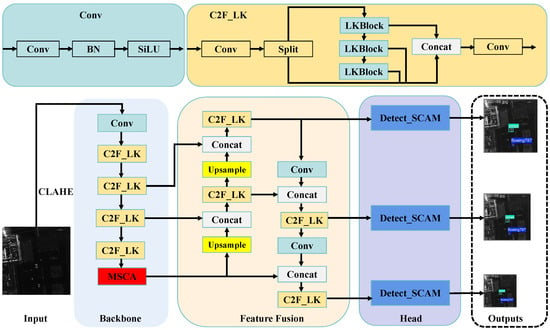
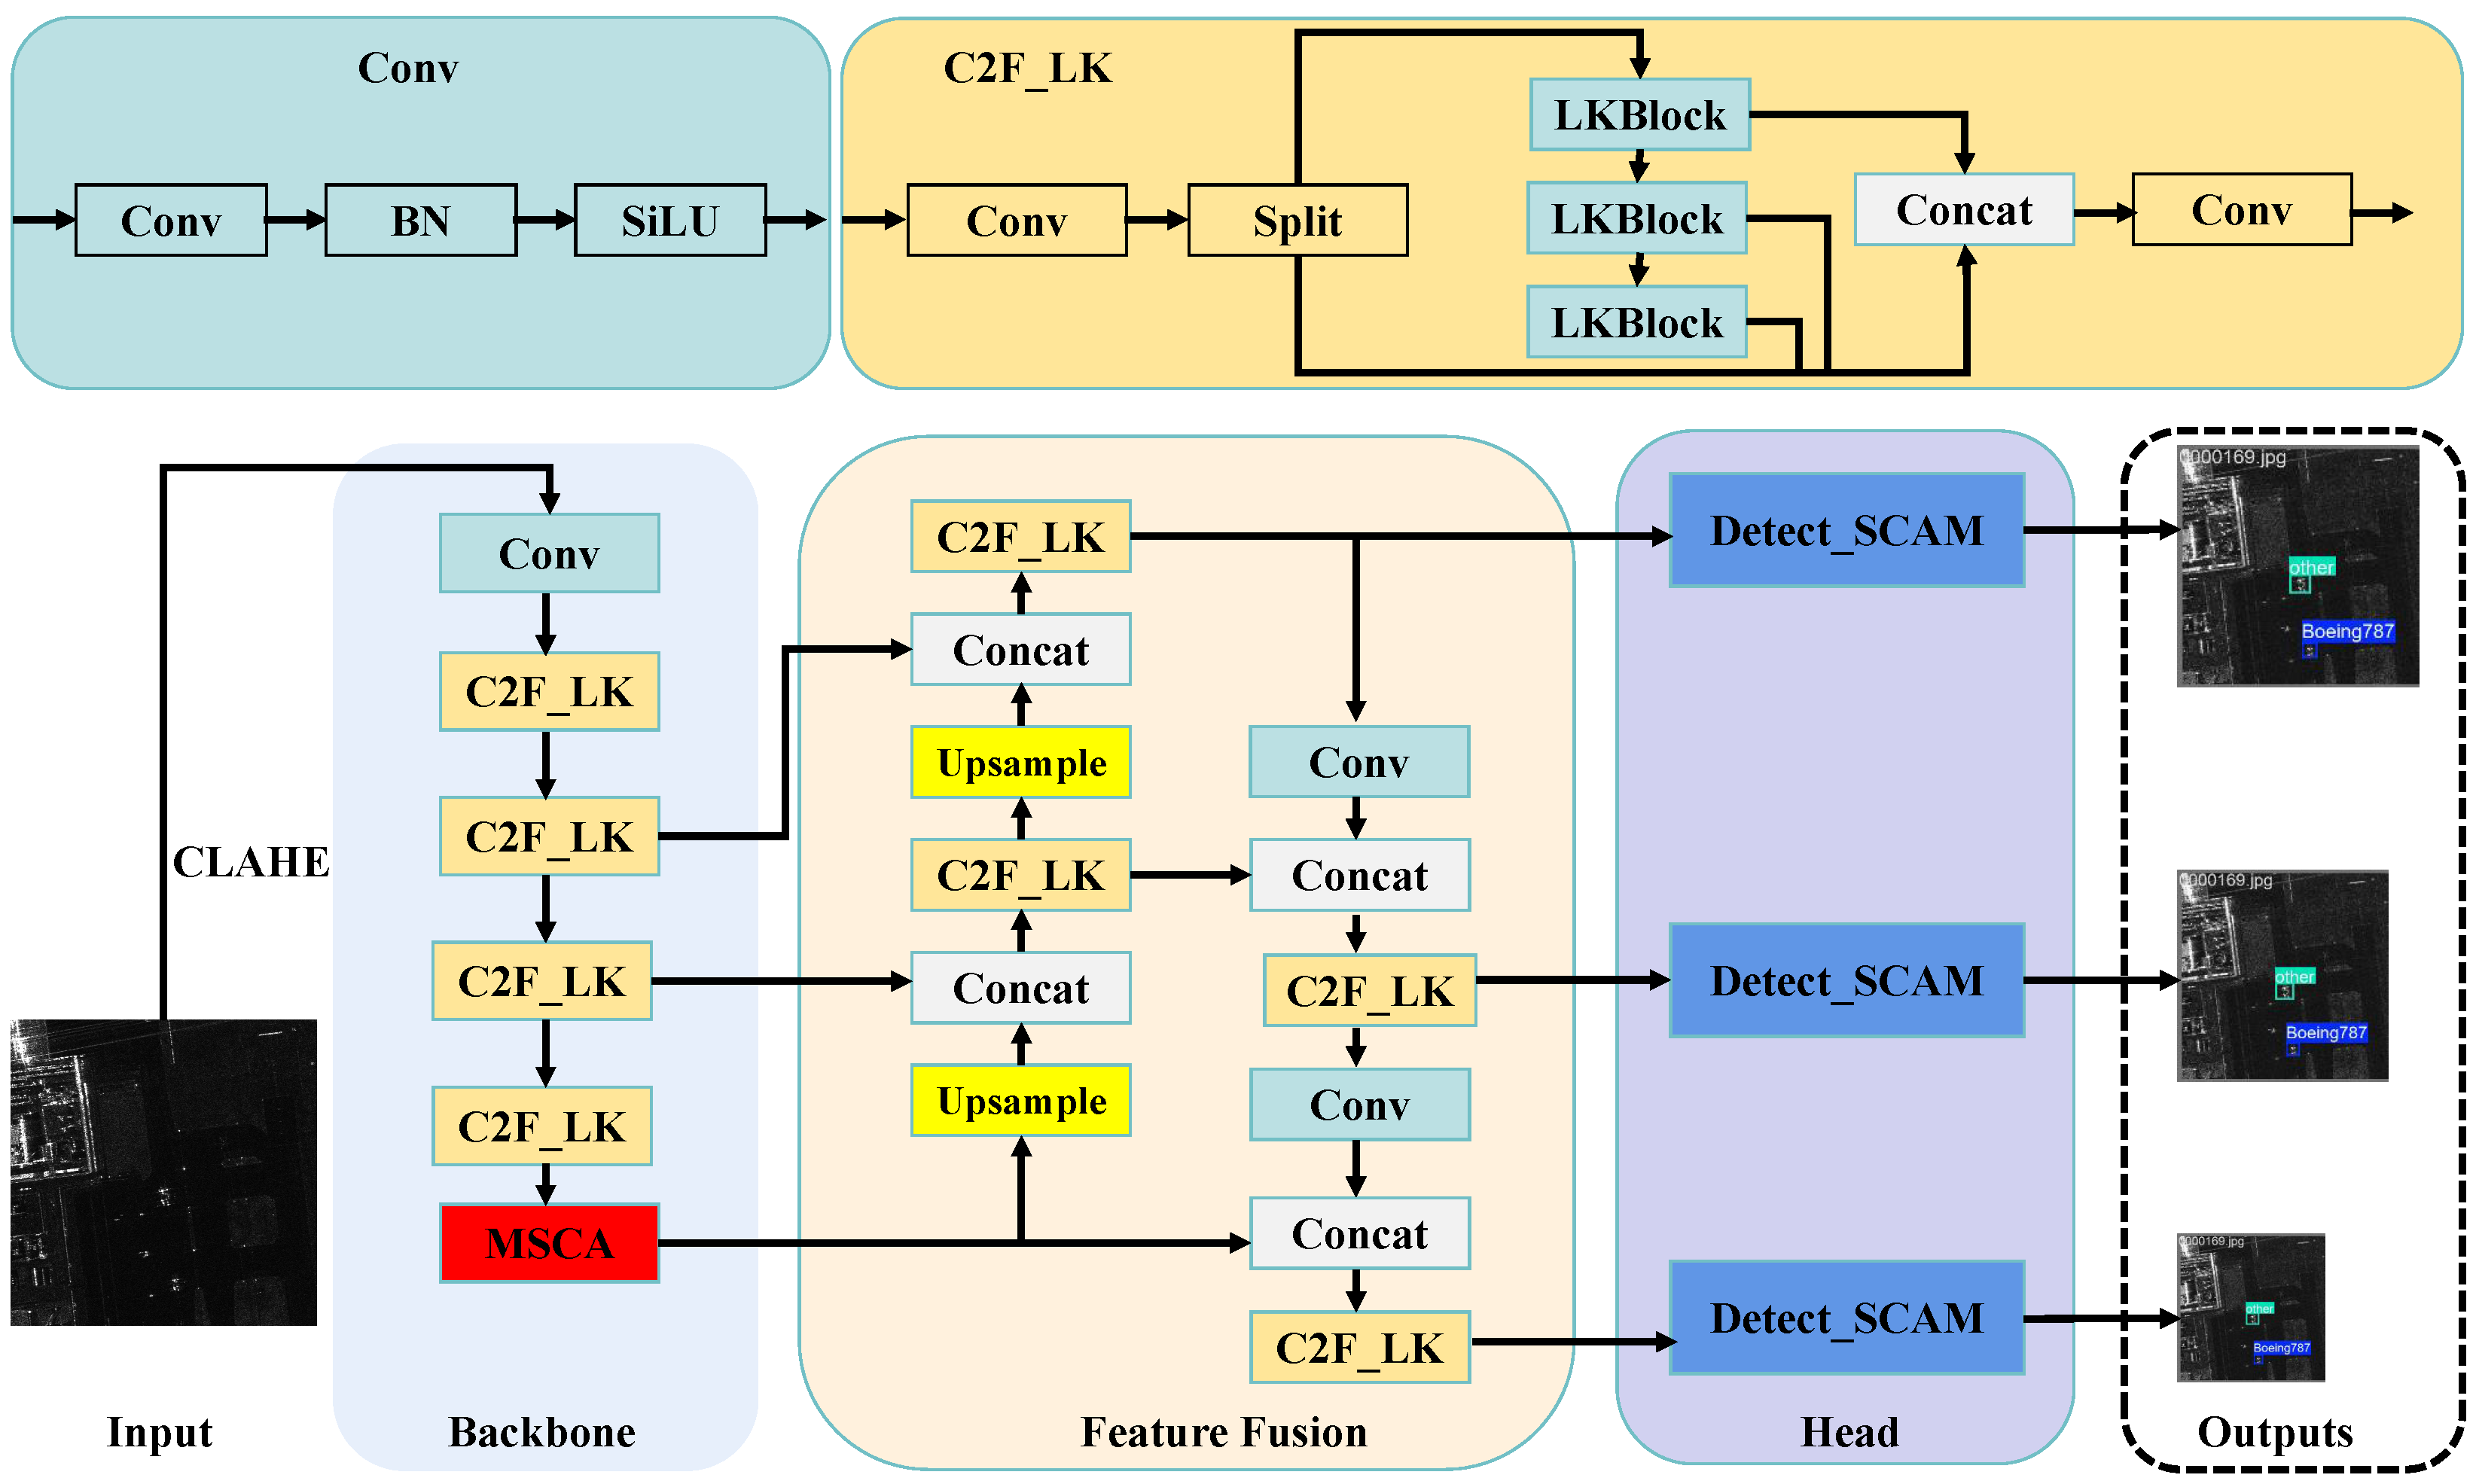
This paper proposes a novel model named CCS-Net for aircraft target detection in SAR images, with the overall architecture illustrated in Figure 2. To address the noise interference problem inherent in SAR imagery, Contrast-Limited Adaptive Histogram Equalization (CLAHE) is first employed for image preprocessing. The proposed CCS-Net model consists of three sequential stages: (1) The feature extraction stage utilizes newly designed C2F_LK and Multi-scale Context Aggregation (MSCA) modules to capture multi-scale features. (2) The feature fusion stage employs an FPN-PAN architecture to effectively integrate multi-scale information. (3) The detection stage incorporates a novel SCA-Head module to achieve precise detection of targets across different scales. Furthermore, the loss function was specifically optimized during the training process. The subsequent sections provide comprehensive descriptions of the proposed model and methodology.
Figure 2.
Framework of the proposed CCS-Net model. The CCS-Net architecture consists of a feature extractor, feature fusion, and a detection head. Initially, the input CXR image is fed into the feature extractor, generating three distinct feature scales. Subsequently, the feature fusion process is carried out using the FPN-FAN technique, resulting in the creation of new features. These fused features are then subjected to detection and classification using the SCA-Head approach. Finally, the final outputs are obtained.
3.1. Contrast-Limited Adaptive Histogram Equalization (CLAHE)
In order to address the challenges posed by low contrast and coherent speckle noise in SAR imagery, the Contrast-Limited Adaptive Histogram Equalization (CLAHE) [32] technique is employed as a preprocessing step. Conventional histogram equalization methods operate on the entire image. Conversely, CLAHE processes the image in small contextual regions, applying local contrast enhancement while limiting noise amplification through a clipping threshold. This approach has been shown to improve the local contrast of aircraft targets against complex backgrounds, making it easier to extract features in subsequent network stages. Preprocessed images demonstrate significantly improved visual interpretability, providing a more discriminative input for the detection network while maintaining computational efficiency.
In this work, CLAHE is employed primarily for local contrast equalization rather than for explicit speckle-noise reduction. Its objective is to enhance the prominence of aircraft high-backscatter regions relative to the background while carefully preserving the subtle scattering patterns of small-scale targets. This pre-processing strategy maintains the fidelity of fine-grained features without introducing over-smoothing, which is particularly beneficial for the lightweight backbone network that follows.
3.2. CNN-Based Feature Extractor
Feature extraction plays a critical role in the detection task. To address the challenge of small target sizes in SAR images and achieve effective multi-scale feature representation, this paper designs a C2F_LK module and an MSCA module for feature extraction.
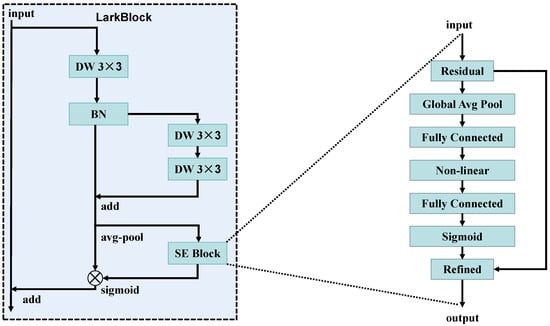
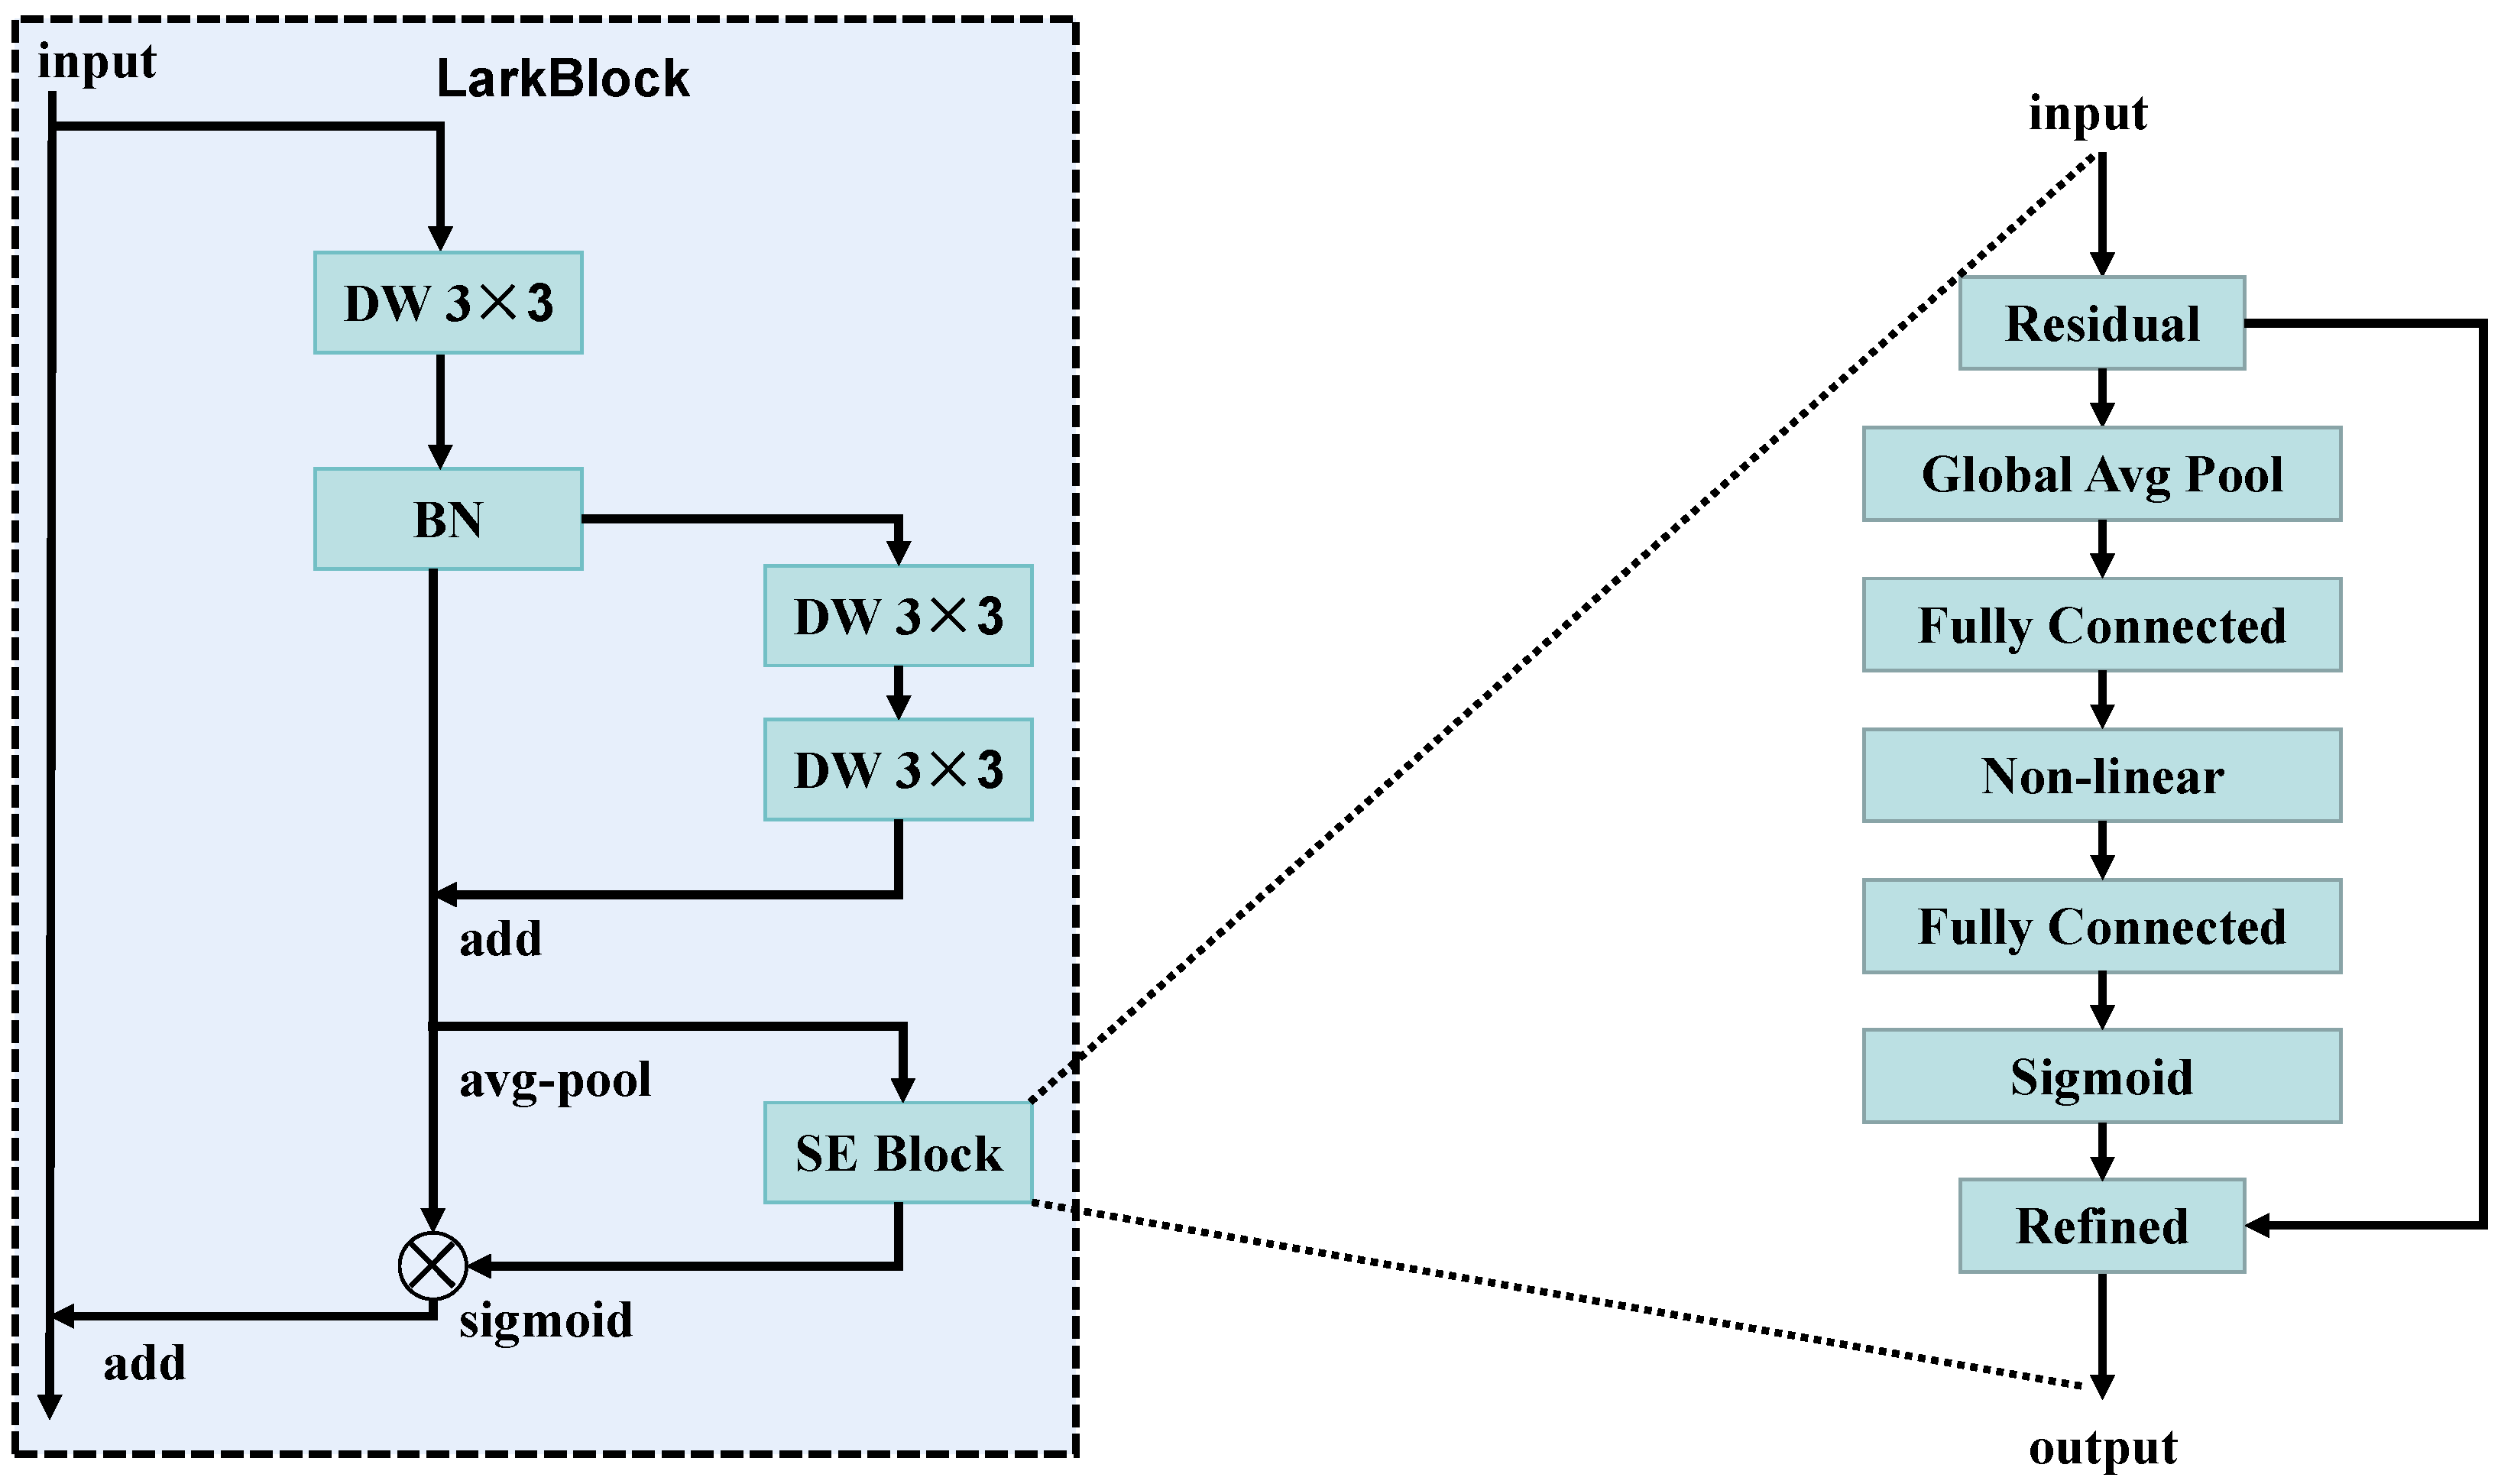
C2F_LK: As the core component of the feature extraction stage, the C2F_LK module is designed to achieve an expansive receptive field and highly expressive feature representation under a computationally efficient framework. Its fundamental building block is the LarkBlock unit, whose detailed structure is illustrated in Figure 3. During training, the module employs depthwise separable convolution (DW Conv) to effectively enlarge the receptive field without introducing significant additional parameters, thereby capturing richer contextual information. The LarkBlock module integrates two key technical strategies:
Figure 3.
Architecture of the lightweight LarkBlock module integrated with an attention mechanism.
First, it extensively utilizes depthwise separable convolution in place of standard convolution. This technique decomposes the convolution process into a depthwise convolution followed by a pointwise convolution, substantially reducing both computational cost and the number of parameters—making it a cornerstone of the lightweight design of the model.
Second, a lightweight squeeze-and-excitation (SE) attention mechanism [33] is embedded within the feature flow. This mechanism begins by squeezing global spatial information through global average pooling, producing channel-wise descriptors. The feature is then excised via a gating mechanism composed of two fully connected layers, which learn nonlinear dependencies among channels. Finally, a Sigmoid activation generates channel-wise attention weights between 0 and 1, which are used to recalibrate the original features. This process enables the model to adaptively emphasize informative feature channels while suppressing less relevant or noisy channels, significantly enhancing the discriminative power of the output features.
Additionally, skip connections are incorporated to improve training stability and prevent overfitting, particularly beneficial for maintaining detection performance on small aircraft targets in complex SAR scenes.
Many improved YOLO-variant SAR detectors employ the vanilla C2F block for feature transformation. By contrast, the proposed C2F_LK integrates LarkBlock into the original C2F architecture. Leveraging depthwise separable convolution for receptive-field expansion with negligible parameter overhead and a compact SE attention branch, C2F_LK is specifically tailored for SAR aircraft. Unlike vanilla C2F for basic feature mapping, it captures dispersed aircraft scattering responses and adaptively suppresses speckle-corrupted noisy channels under lightweight deployment constraints.
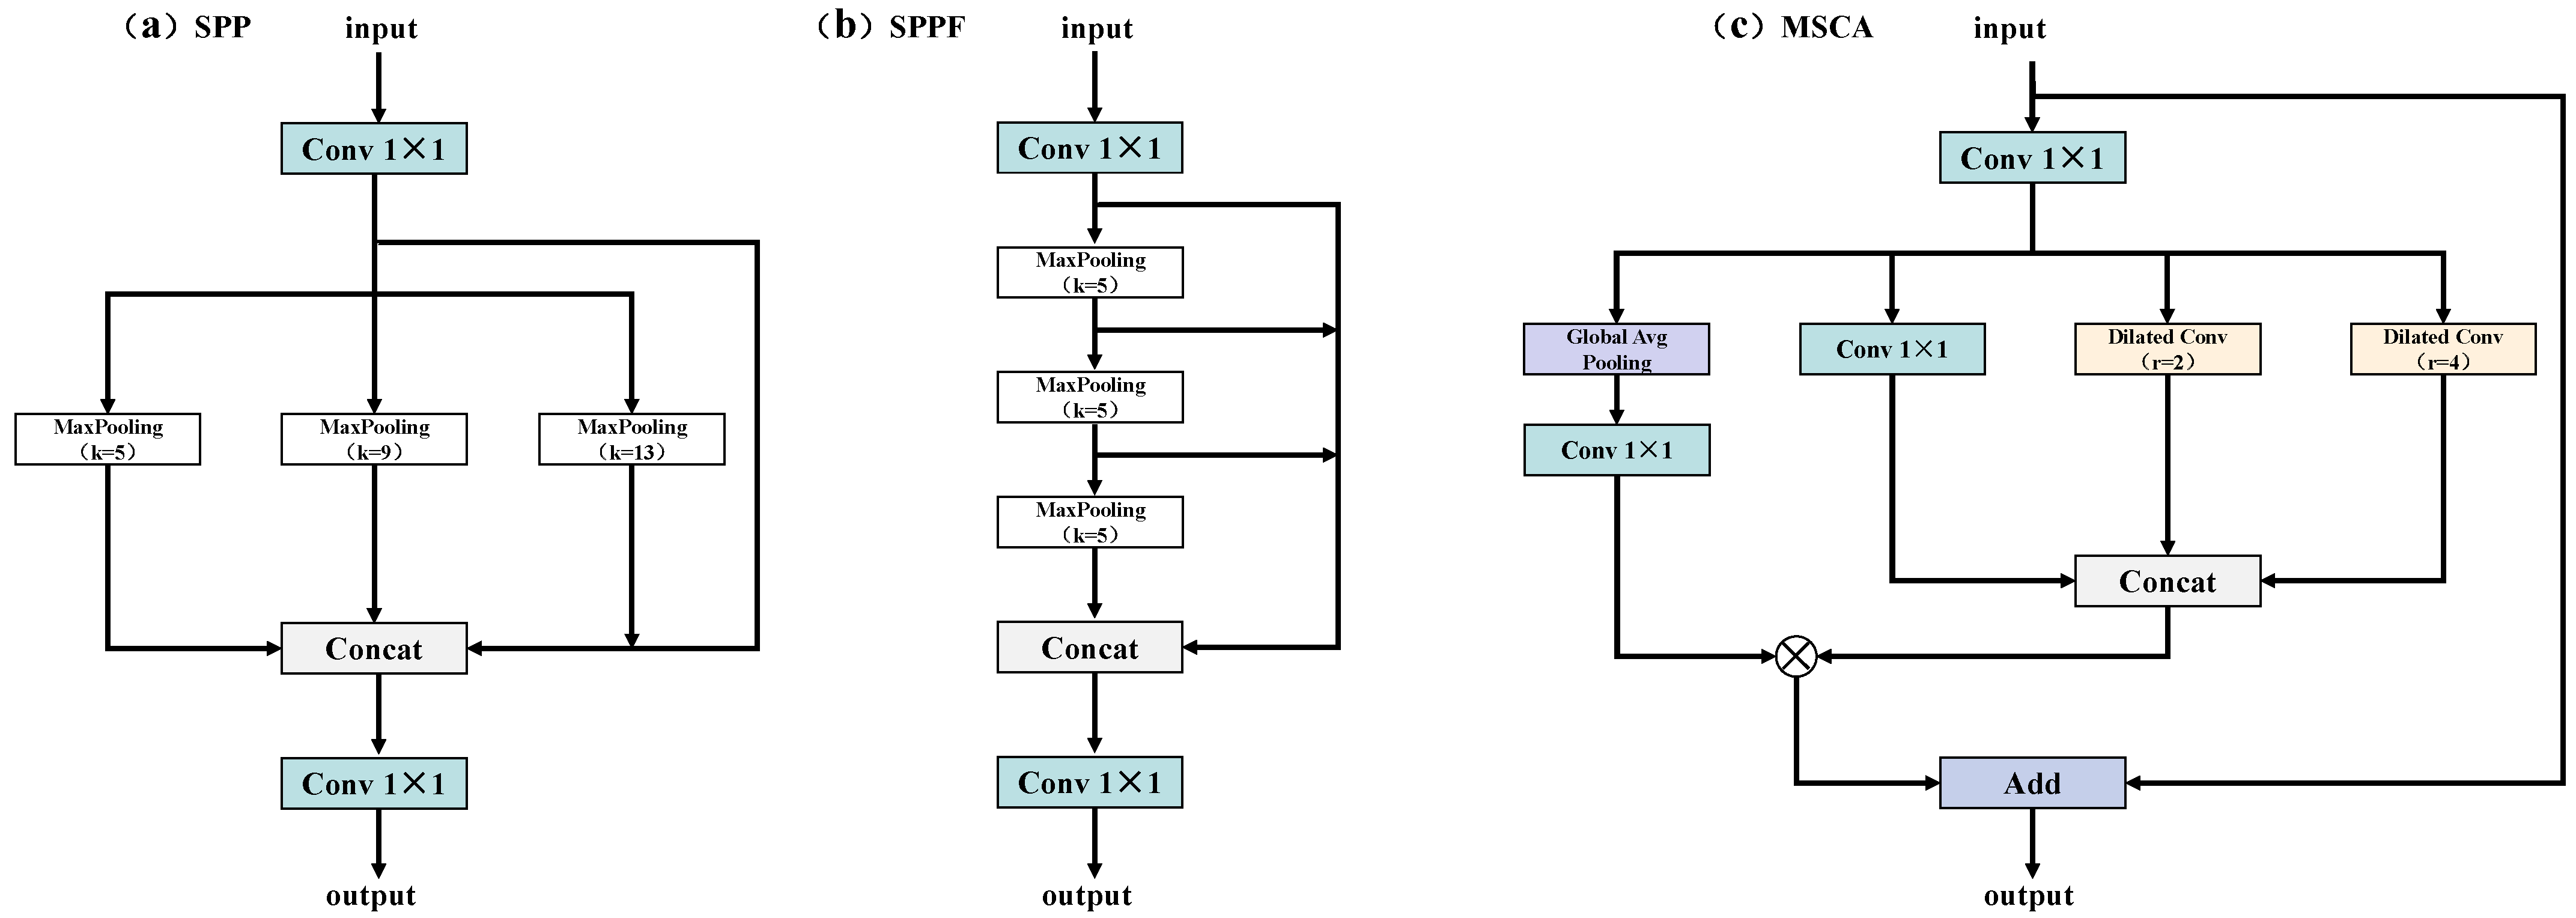
Multi-scale Context Aggregation (MSCA): While traditional serial multi-scale modules capture context through fixed-pattern pooling, their receptive field expansion is rigid and lacks dynamic cross-scale interaction. To address the varying sizes of aircraft targets and complex backgrounds in SAR images, this study proposes the MSCA module. It employs parallel multi-branch dilated convolutions and efficient interaction mechanisms for more flexible and powerful multi-scale context aggregation. As shown in Figure 4, the core of MSCA uses convolutional layers with different dilation rates to extract multi-scale features. A lightweight channel attention mechanism then enables adaptive fusion of these features, significantly boosting the model’s capability to recognize multi-scale targets.
Figure 4.
Comparison of pooling-based feature aggregation structures: (a) SPP, (b) SPPF, and (c) the proposed MSCA module.
Common multi-scale modules include SPP, SPPF, and conventional ASPP. SPP and SPPF suffer from limited cross-scale interaction caused by fixed max-pooling operations, while standard ASPP simply concatenates outputs from dilated convolution branches. By introducing an additional global average pooling branch and a lightweight channel-attention fusion path, MSCA re-weights features from each dilated branch before residual fusion. This design eliminates the equal-weight limitation of ASPP and enables better adaptation to the large-scale variations of SAR aircraft targets.
3.3. Feature Fusion
To address the performance degradation in SAR image target detection caused by significant scale variations, weak features of small targets, and spatial information loss in deep networks, this paper adopts a dual-path Feature Pyramid Network (FPN + PAN) integrating top-down and bottom-up pathways for multi-scale feature fusion. This architecture operates through two complementary processes: First, the top-down FPN pathway progressively upsamples deep, high-level semantic features and integrates them with mid-level and shallow features through lateral connections, thereby enriching the semantic representation of shallow layers. Subsequently, the bottom-up PAN pathway down-samples spatially rich shallow features and further fuses them with corresponding mid-level and deep features, enhancing the localization precision of deep layers. This bidirectional fusion mechanism effectively achieves complementary enhancement of semantic information and spatial details across different scales. The integrated architecture provides subsequent detection modules with more discriminative and scale-adaptive feature representations, significantly improving detection performance for targets with diverse sizes and complex characteristics in SAR imagery.
3.4. Spatial Coordinate Attention Head (SCA-Head)
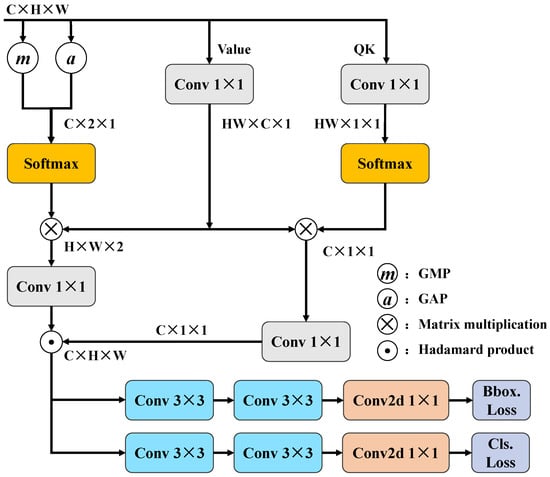
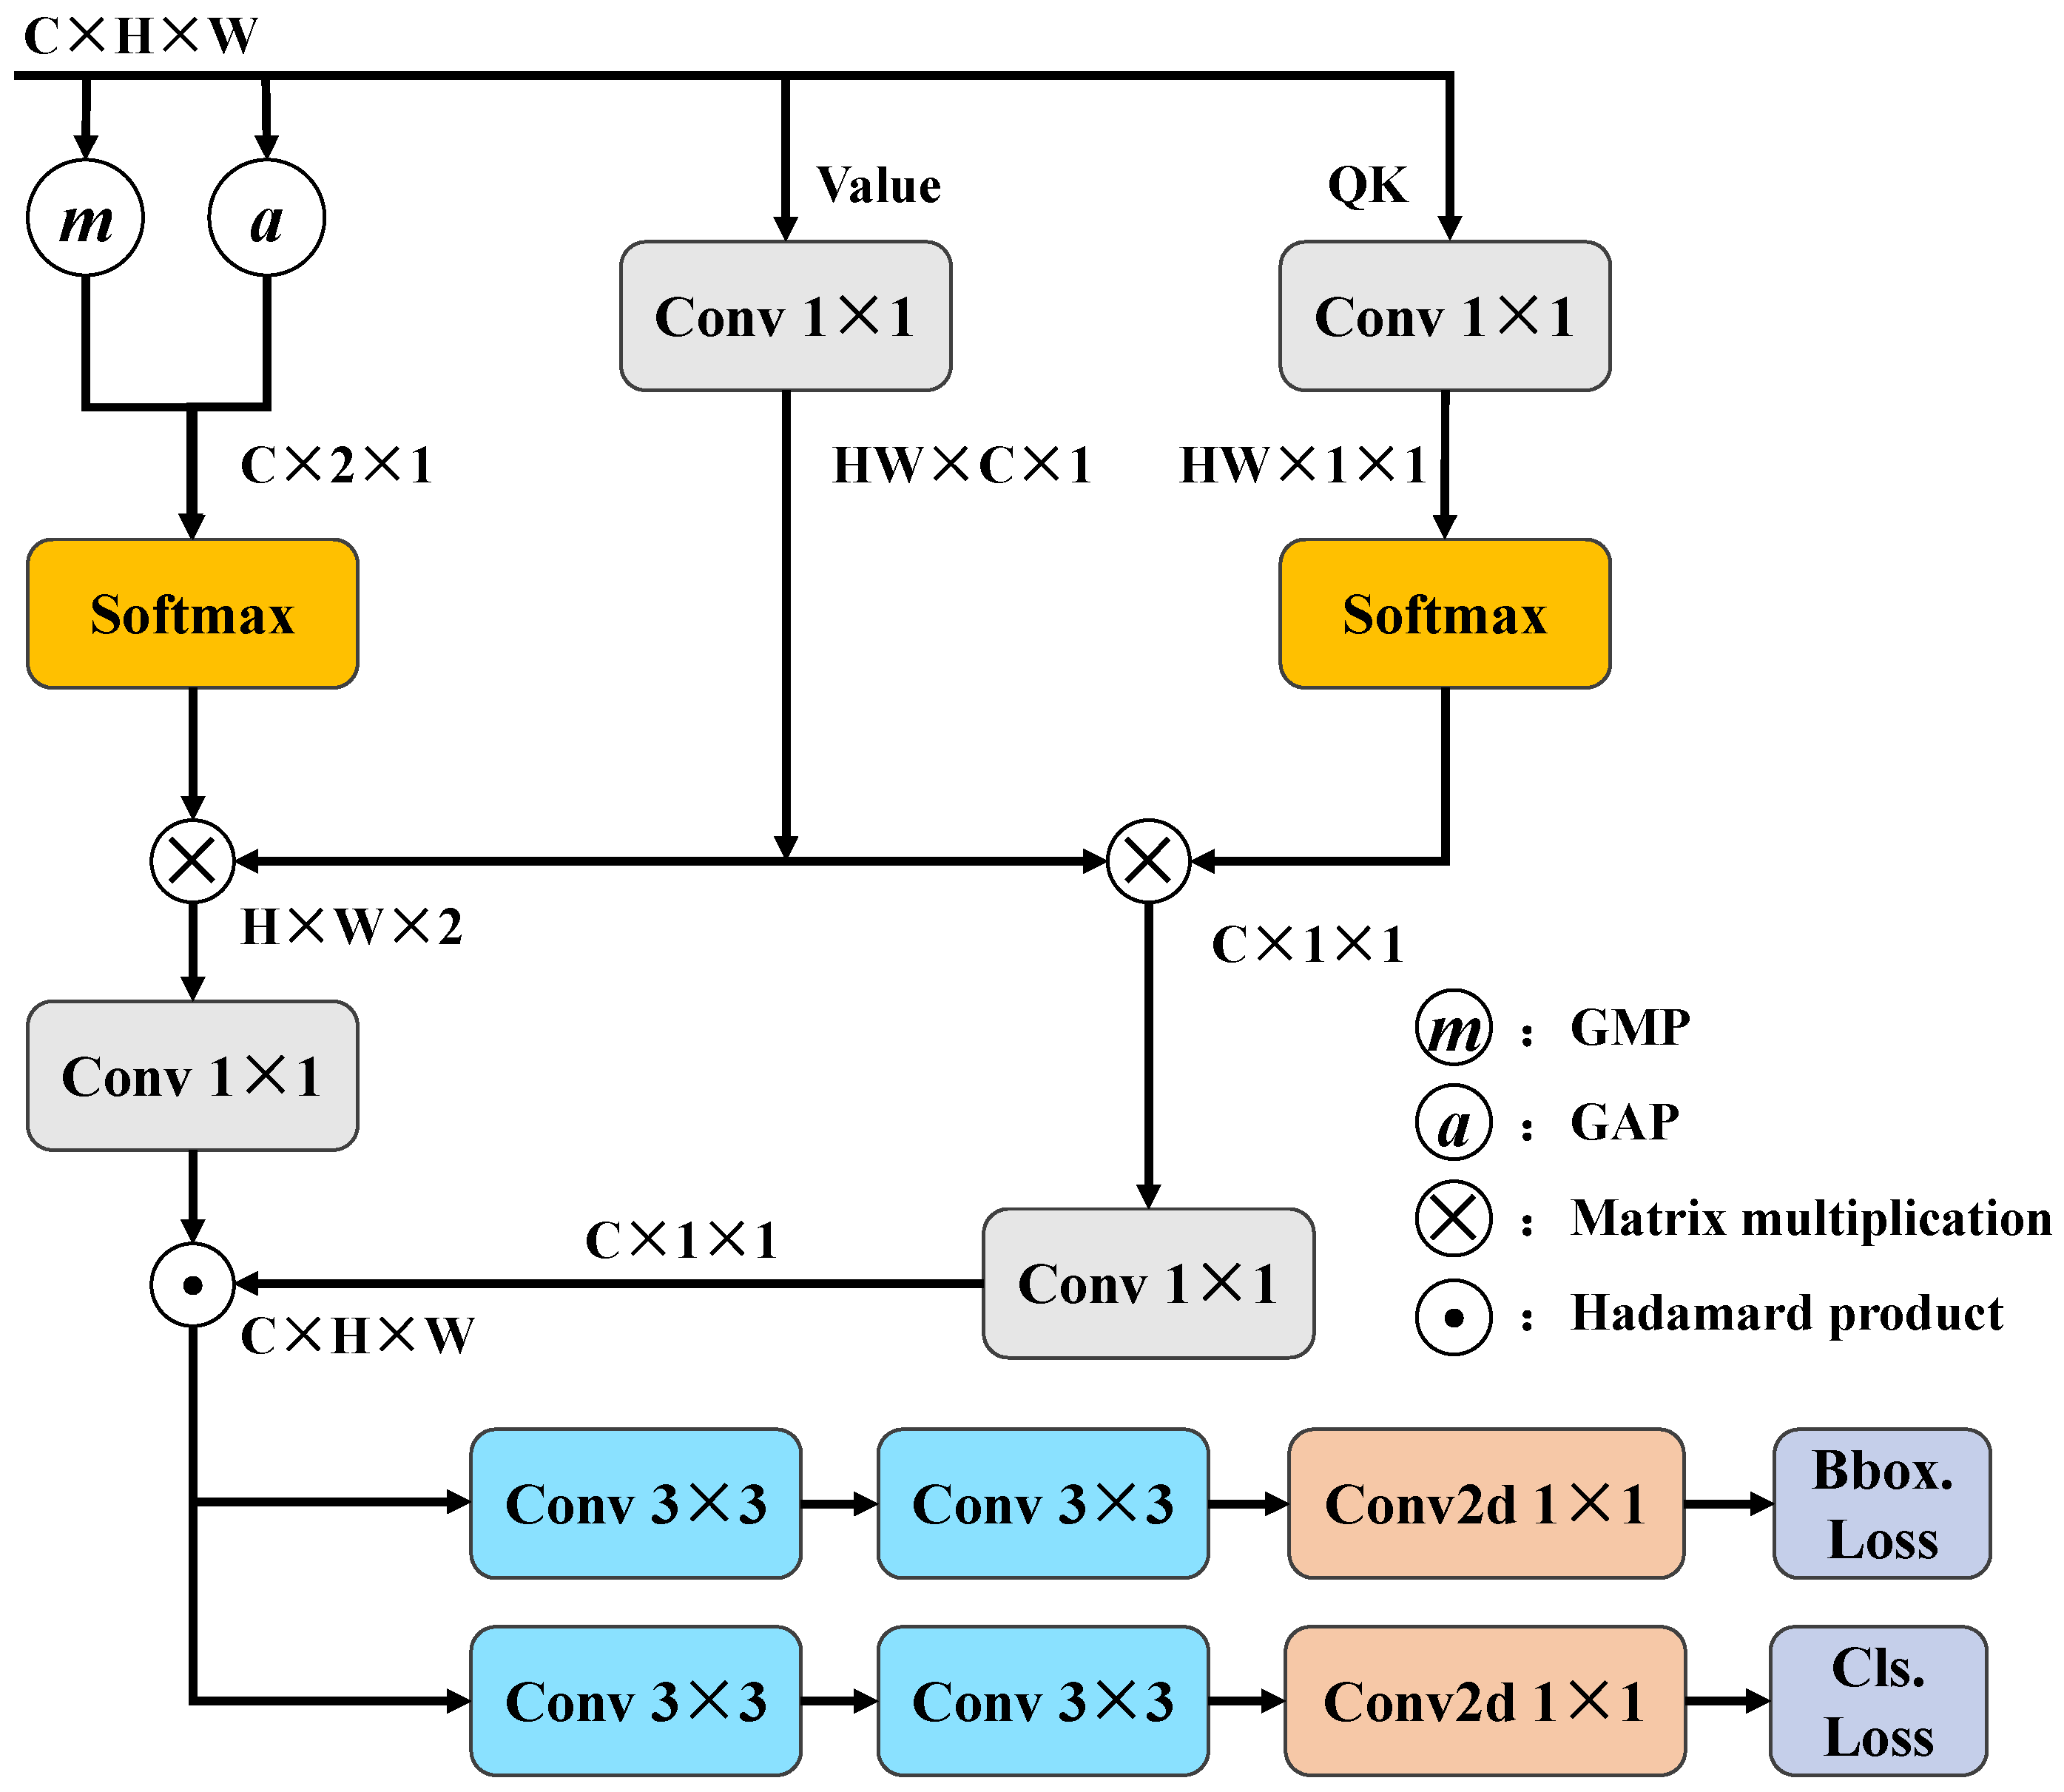
This paper proposes a novel detection-head structure, SCA-Head, to enhance the detection accuracy of aircraft targets in SAR images. This architecture innovatively integrates our independently designed Spatial Coordinate Attention Module (SCAM) [34] with the multi-scale detection pipeline, operating through the following core mechanism: As demonstrated in Figure 5, the input feature map () is initially processed through two distinct convolutional layers to yield the Query (Q) and Key (K) tensors. Through interactive computation and Softmax normalization, these tensors produce an -dimensional coordinate attention weight map that captures the spatial positional relationships of targets. This weight map precisely extracts critical spatial distribution information along the height and width dimensions of the image. Concurrently, the original feature map is processed through an alternative pathway consisting of convolutions to generate the Value (V) tensor. Finally, through the adaptive fusion of the coordinate attention weights with the Value tensor, the detection head significantly enhances its focus on regional targets prior to prediction generation, thereby achieving precise classification and localization, even in complex backgrounds.
Figure 5.
Architecture of Spatial Coordinate Attention Head (SCA-Head).
Prebuilt coordinate or spatial attention modules are often deployed as standalone units outside the detection head. Differing from this external scheme, SCA-Head embeds spatial max and average pooling alongside coordinate-aware query–key interaction within the detection pipeline. It generates spatial coordinate weight maps to strengthen aircraft scattering responses and elevate small aircraft localization performance under heavy background clutter.
3.5. Loss-Function Optimization
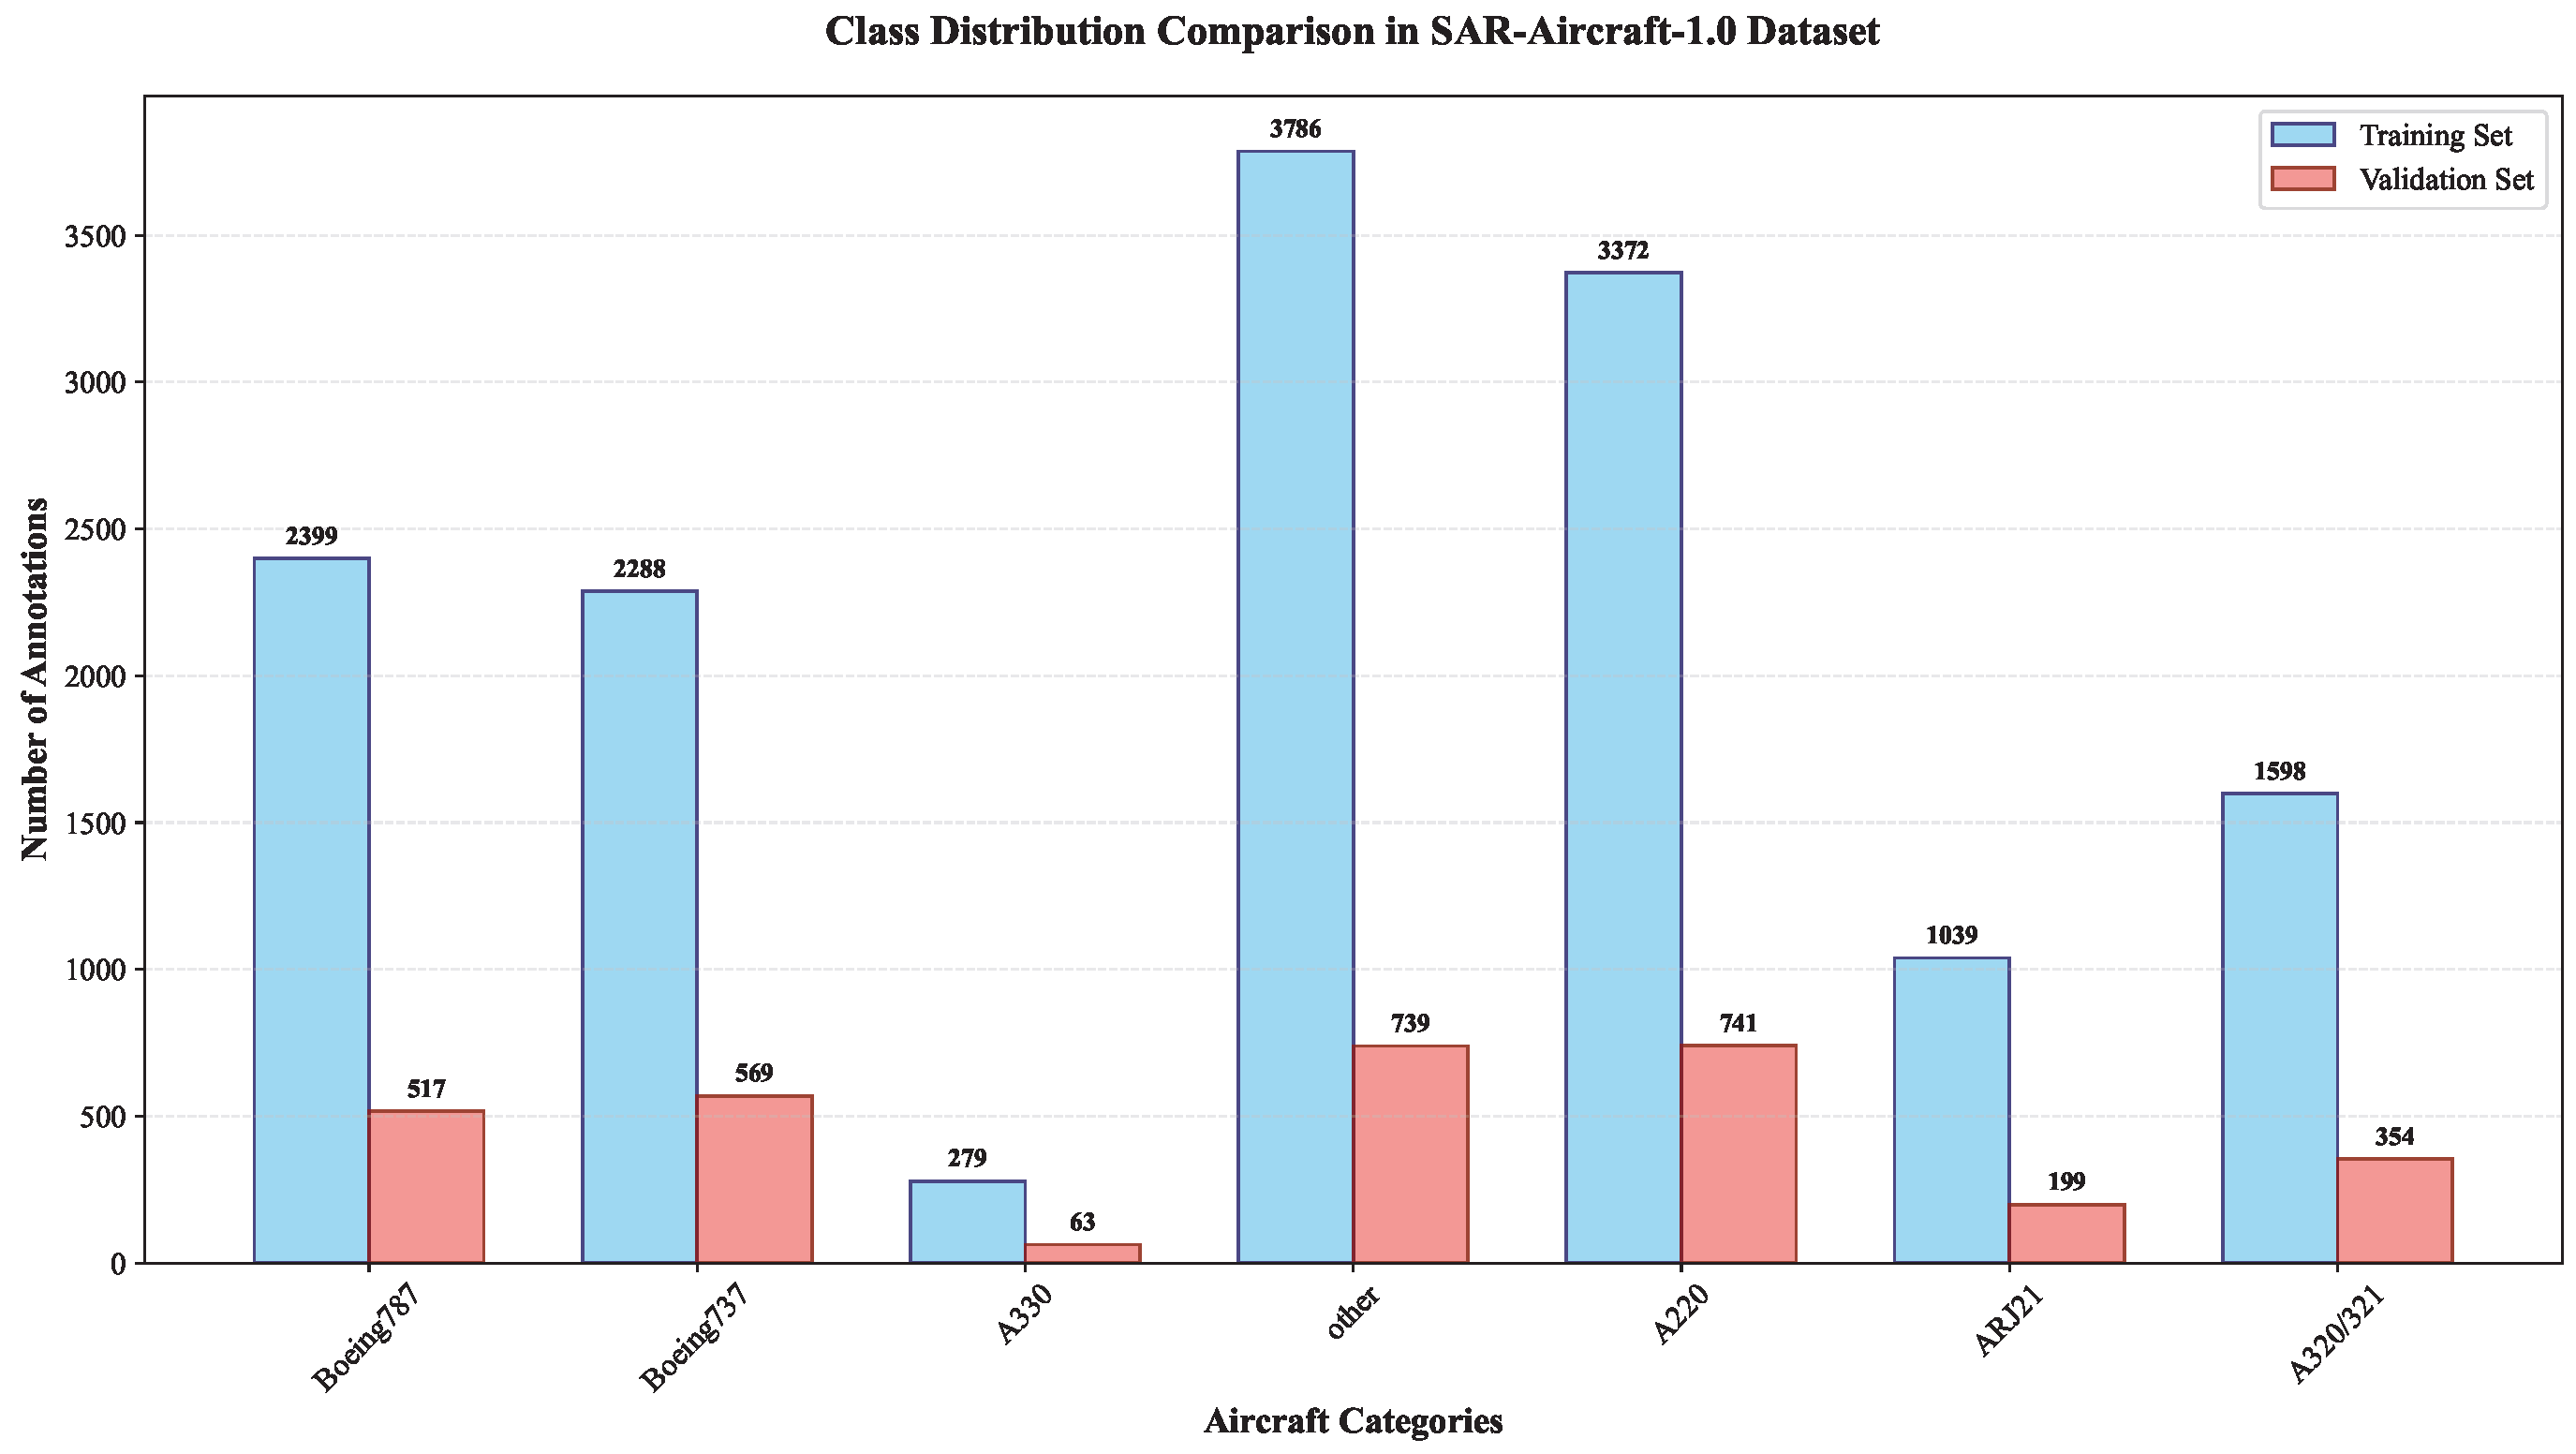
As shown in Figure 6, in SAR aircraft detection datasets, significant disparities in the number of instances across different categories often lead to severe class imbalance. Additionally, the conventional use of hard labels in classification tasks encourages the model to become overconfident in its predictions, increasing its susceptibility to overfitting on noise and specific patterns within the training data, thereby compromising generalization performance. To address these issues, this study incorporates label smoothing [35] into the binary cross-entropy (BCE) loss, resulting in a refined loss function termed BCELabelSmoothing. Label smoothing BCE softens one-hot labels to reduce model overconfidence, relieve dataset class imbalance and avoid heavy penalties on hard samples.
Figure 6.
Distribution of training and validation images over 7 aircraft categories in the SAR-Aircraft-1.0 dataset.
In classification tasks, the ground-truth label vector typically follows a one-hot encoding scheme, where the target class is assigned a probability of 1 and all non-target classes are assigned 0. This representation, denoted as , is formally defined in Equation (1). To optimize models under this framework, the cross-entropy loss is widely adopted as the objective function for classification problems. A special case for binary classification is the Binary Cross-Entropy () loss, as expressed mathematically in Equation (2).
where is the predicted probability value.
During training, label smoothing mitigates model overconfidence by replacing the hard one-hot labels with a softened distribution that incorporates a uniform prior. Thus, the original ground-truth label vector () is adjusted to a smoothed variant (), as defined in Equation (4).
where K denotes the number of classes and is the smoothing factor, which is usually taken as a small positive number, used to control the degree of smoothing of the label. By introducing the smoothing factor (), the degree of overconfidence of the model for the training samples can be reduced, thereby improving the generalization ability and robustness of the model, while the parameter was deliberately configured to a fixed value of 0.1. The loss of BCELabelSmoothing is calculated as shown in Equation (4).
where each SAR image is labeled as a one-hot vector. In our conducted experiments, a label is obtained after the calculation of the y label in Equation (3). The value of K was determined to be 7.
4. Experiment
In this section, this study proposes a comprehensive description of our experimental setup. This section describes the public dataset used in this study, along with the experimental parameter configurations and training methodology. Finally, we present the evaluation metrics adopted for performance assessment, along with detailed explanations of their significance.
4.1. Dataset
In this work, we validate the proposed CCS-Net on four public SAR datasets, including the SADD and SAR-Aircraft-1.0 aircraft detection datasets, as well as the HRSID and SSDD ship detection datasets. Experimental results across all datasets support a comprehensive analysis of the model’s detection performance and generalization capability.
SADD [36] is a public synthetic aperture radar dataset designed for aircraft detection tasks. The dataset is collected from multiple satellite sources, including Gaofen-3 (GF-3) and TerraSAR-X, focusing specifically on single-aircraft target detection. As shown in Table 1, the dataset contains 2968 SAR images with 7835 annotated aircraft instances. All images are uniformly preprocessed to a fixed size of pixels to facilitate deep learning model input and training. The data covers multiple major airports worldwide, encompassing various parking configurations, background scenes, and imaging conditions, providing effective support for robust evaluation of aircraft detection algorithms.
Table 1.
Distribution of training and validation sets for SADD, SAR-Aircraft-1.0, HRSID, and SSDD datasets.
SAR-Aircraft-1.0 [31] is an aircraft detection dataset with fine-grained recognition labels, collected from Gaofen-3 satellite with 1 m resolution using single-polarization Spotlight imaging mode. It contains seven categories: A320/321, A220, ARJ21, A330, Boeing 737, Boeing 787, and Other. The dataset includes multi-temporal images from different airports, covering large areas with complex backgrounds. It consists of four different image sizes—, , , and pixels—containing a total of 4368 images. The total number of aircraft instances is 17,943. The data is divided into training and validation sets in an 8:2 ratio. As demonstrated in Figure 6, there is an imbalance in the class distribution.
HRSID [37] is a publicly available benchmark for ship detection in high-resolution SAR imagery. It contains 5604 images of 640 × 640 pixels, acquired from TerraSAR-X, Sentinel-1, and TanDEM-X under diverse imaging modes. The dataset includes 16,951 annotated ship instances across open-sea, coastal, and port scenes, spanning various resolutions, polarizations, and sea conditions. It is randomly split into training and validation sets at an 8:2 ratio.
SSDD [38] is a widely used benchmark in SAR ship detection, complementing HRSID with simpler offshore backgrounds and sparser ship distributions. It comprises 1160 SAR images with approximately 2587 annotated ship instances. All images are 500 × 500 pixels and contain only a single target category.
4.2. Evaluation Metrics
In this study, we employed multiple evaluation metrics to comprehensively assess the performance of the proposed CCS-Net model. For detection accuracy assessment, we selected Precision (P), Recall (R), Average Precision (AP), and mean Average Precision (mAP), which have been used in most relevant work [39,40]. To evaluate model efficiency, we utilized parameter count and computational complexity as lightweight indicators. The mathematical formulations of these metrics are presented below:
In this context, TP, FP, and FN denote the quantities of true positives, false positives, and false negatives, respectively. Precision quantifies the reliability of the model’s positive predictions by representing the proportion of correctly identified positive instances among all instances predicted as positive. Conversely, recall assesses the model’s capacity to accurately identify all actual positive instances, thereby indicating the comprehensiveness of detection.
In object detection tasks, precision and recall frequently exhibit an inverse relationship. To facilitate a comprehensive evaluation of a model’s performance across varying recall levels, the Average Precision (AP) metric is employed. AP is defined as the area under the Precision-Recall (PR) curve.
AP values provide a comprehensive reflection of a model’s performance in detecting objects in a single category. To evaluate the model’s overall performance in multi-category tasks, we use Mean Average Precision (mAP) as the important evaluation metric:
where k denotes the total number of categories. By averaging AP values across all categories, mAP provides a comprehensive measure of model performance and has become the primary evaluation standard in the field of object detection. Additionally, to better evaluate model performance, this paper assesses competing models using parameters, GFLOPs, as well as simulated inference latency (FPS) and memory consumption (MB).
4.3. Implementation Details
The CCS-Net model was implemented using the PyTorch 2.9.0 framework. All experiments were conducted on a workstation equipped with an NVIDIA GeForce RTX 4060 GPU. The proposed CCS-Net model was evaluated on both SADD and SAR-Aircraft-1.0 datasets. Following standard practice, we split each dataset into training and testing sets with an 8:2 ratio. As shown in Table 2, the model was trained for 100 epochs with a batch size of 16, using an initial learning rate of 0.0004. Optimization was performed using the Adam optimizer with default parameters.
Table 2.
Parameters for training.
5. Results and Analysis
This section presents a comprehensive experimental evaluation of the proposed CCS-Net model on benchmark datasets. Through systematic ablation studies, we conduct an in-depth analysis of the contributions made by each key component. Furthermore, comparative experiments with state-of-the-art methods demonstrate the effectiveness of our approach. The experimental results provide substantial evidence for performance assessment and model optimization.
5.1. Comparison with State-of-the-Art Methods
As shown in Table 3, we conducted a systematic evaluation of the proposed method on the SAR-Aircraft-1.0 dataset and performed comprehensive comparisons with several recently proposed advanced methods. The experimental results demonstrate that our method achieves an excellent overall detection accuracy, showing superior performance across multiple key metrics.
Table 3.
Comparisons of detection performance(%) on SAR-Aircraft-1.0 [31]. The results of each category are computed.
According to the category-specific detection results, our method achieves optimal detection accuracy for aircraft types including A220, ARJ21, Boeing 737, and Boeing 787. The detection accuracy for the Boeing 737 is particularly notable, at 97.7%, representing a significant improvement of approximately 20.6 % compared to the 77.1% reported by Zhou et al. [42]. The detection accuracy for the A330 and A320/321 categories is markedly lower than that reported by Zhou et al. [41], maintaining relatively high levels of 93.0% and 95.8%, respectively, demonstrating stable detection capability across different types of aircraft. Our lightweight design compromises fine-grained feature extraction to reduce computational overhead, and the insufficient number of annotated samples for the two categories further degrades detection performance. The detection precision of A330 and A320/321 lags behind existing state-of-the-art methods for the two reasons above. Targeted sample augmentation will be adopted to alleviate this deficiency in follow-up research.
Regarding comprehensive evaluation metrics, our method achieves 96.6% in mAP@0.5, outperforming all comparative methods, reflecting the model’s excellent overall detection performance under loose overlap threshold conditions. Simultaneously, we obtained 93.5% in precision, showing improvements compared to Zhou et al. [40] (91.5%). These results indicate that our method achieves a better balance between localization precision and classification accuracy, validating the effectiveness of the proposed improvement strategies. Compared with the latest state-of-the-art methods, specifically those of Zhou et al. [45] and Junos et al. [46], our CCS-Net demonstrates superior overall performance. While Junos et al. achieved competitive results with a 96.0% mAP@0.5, our method surpasses theirs by 0.6% in mAP@0.5 and significantly improves localization accuracy by 1.3% in mAP@0.75, confirming the effectiveness of our proposed architecture in precise target localization.
To further validate the effectiveness of the proposed CCS-Net model for aircraft detection in SAR images, we conducted comprehensive comparative experiments with several mainstream detection models, including Faster R-CNN, SSD, and the YOLO series, on the SAR-Aircraft-1.0 dataset. The results are summarized in Table 4.
Table 4.
Comprehensive performance(%) comparison of object detection models on the SAR-Aircraft-1.0 dataset.
As shown in Table 4, in terms of detection accuracy, our method achieved optimal performance across four key metrics: Precision (P), Recall (R), mAP@0.5, and mAP@0.75. Specifically, the proposed CCS-Net attained 96.6% mAP@0.5, representing a 2.0 % improvement over the best-performing baseline YOLOv8 (94.6%). Furthermore, it achieved 73.8% mAP@0.75, significantly outperforming all other comparative models. These results demonstrate that our method maintains high recall while achieving superior localization accuracy and classification consistency. Regarding model efficiency, CCS-Net contains only approximately 0.97M parameters, which is substantially fewer than YOLOv8 (3.2M) and YOLOv10 (2.7M), representing the lowest parameter count among all compared models. Its computational complexity is 7.7 GFLOPs, which is slightly higher than YOLOv11 (6.3 GFLOPs) but significantly lower than the two-stage Faster R-CNN detector (135.7 GFLOPs). This demonstrates excellent lightweight characteristics. Limited by current experimental facilities, physical inference measurements on real embedded edge hardware are unavailable. Therefore, simulated FPS and peak memory consumption under typical edge-device constraints are supplemented in Table 4 for reference. It should be noted that these simulated values inevitably deviate from practical hardware outputs. Complete hardware deployment and field validation for real-time SAR reconnaissance will be explored in our future work.
Consequently, CCS-Net has been demonstrated to establish an optimal balance between the two, achieving significant improvements across multiple metrics while substantially reducing the parameter count. Moreover, it exhibits superior overall performance compared to conventional methods. It demonstrates robust detection capability across most fine-grained aircraft categories, with particularly notable gains for specific types under challenging conditions. These comprehensive results validate the effectiveness and advancement of our proposed approach for SAR image aircraft target detection tasks.
5.2. Analysis of the Feature Extractor
As shown in Table 5, to validate the effectiveness of the proposed C2F_LK and MSCA modules, we conducted ablation studies on the SAR-Aircraft-1.0 dataset under identical experimental settings. The results demonstrate that both the C2F_LK and MSCA modules exhibit significant advantages across multiple detection metrics.
Table 5.
Performance (%) comparison of different modules on the SAR-Aircraft-1.0 dataset.
The proposed C2F_LK module has been demonstrated to outperform both the C3 and C2F structures in all four metrics: Precision (P), Recall (R), and mean Average Precision (mAP) at 0.5 and 0.75. Specifically, it achieves an mAP@0.5 of 96.6%, representing improvements of 1.0% and 1.7% over C2F and C3, respectively. This finding suggests that, while preserving the same structural parameters, the incorporation of large-kernel convolutions and structural optimizations leads to a substantial enhancement in the model’s capacity to represent features of aircraft targets in SAR images.
Under the same experimental conditions, the MSCA module achieves identical results to C2F_LK across all metrics, yielding the best performance among all compared structures. Compared to the classical SPP and SPPF modules, MSCA improves mAP@0.5 by 1.1% and 0.8%, respectively. This demonstrates that through its multi-scale context aggregation mechanism, MSCA can more effectively integrate feature information from different levels under equivalent experimental settings, thereby enhancing both the robustness and localization accuracy of object detection.
In summary, under strictly controlled experimental conditions, both the C2F_LK and MSCA modules not only achieve optimal performance when evaluated individually but also exhibit full compatibility and complementary effects when combined. Together, they form the core strengths of the proposed model, providing an effective solution for feature extraction and fusion in SAR image-based aircraft detection.
5.3. Evaluation on the SADD Dataset
To evaluate the generalization capability of the proposed model, we conducted a systematic assessment of CCS-Net on the public SADD dataset and performed a comparative analysis with recently reported state-of-the-art methods on the same dataset. The results are summarized in Table 6.
Table 6.
Comparisons of Detection Performance(%) on the SADD Dataset.
Experimental results demonstrate that CCS-Net achieves competitive overall performance on the SADD dataset. In terms of overall detection accuracy, the proposed method attains an mAP@0.5 of 97.7%, significantly outperforming the methods of Yang et al. [48] (87.8%) and Guo et al. [43] (85.6%) and improving upon the method of Chen et al. [39] by 5.7%. This indicates the model’s strong adaptability to different data distributions. Regarding classification and localization accuracy, CCS-Net achieves a precision (P) of 95.1%, the highest among all compared methods, while maintaining a high recall (R) of 93.5%. Furthermore, Junos et al. [46] exhibit strong adaptability, with a 97.2% mAP@0.5; our method achieves 97.7%, securing a 0.5% lead. Moreover, regarding localization quality (mAP@0.75), CCS-Net surpasses the method of Junos et al. by 0.8%, demonstrating the superior robustness of our feature extraction modules across different sensor data distributions.
Notably, under the more stringent localization quality requirement of mAP@0.75, CCS-Net reaches 58.3%, surpassing the 57.1% reported by Chen et al. [39]. This result confirms the model’s consistent detection performance across different IoU thresholds.
These results provide substantial evidence that CCS-Net functions effectively on its primary training dataset and also demonstrate considerable generalization and robustness with respect to novel data. Consequently, CCS-Net establishes a robust technical foundation for effective practical deployment.
5.4. Evaluation on the HRSID and SSDD Datasets
To further evaluate the generalization capability of the proposed CCS-Net under diverse SAR imaging conditions, we conducted additional experiments on two public ship detection benchmarks—namely, HRSID and SSDD. In contrast to the aircraft-specific datasets (SAR-Aircraft-1.0 and SADD) employed in the preceding experiments, HRSID and SSDD present substantial domain shifts, characterized by ship targets of varying sizes, heterogeneous sensor configurations, multiple spatial resolutions, and complex land–sea background interferences.
Quantitative comparisons with several state-of-the-art SAR detection methods are summarized in Table 7. On HRSID, CCS-Net achieves a precision of 93.21%, a recall of 83.16%, and an mAP@0.5 of 92.30%. On SSDD, it attains 98.88%, 97.09%, and 98.91%, respectively. Despite being originally tailored for aircraft detection, our method still yields competitive performance on ship targets, thereby demonstrating encouraging cross-category generalization capacity.
Table 7.
Performance comparison(%) for generalization evaluation on HRSID and SSDD SAR ship-detection datasets.
To further validate the superiority of CCS-Net, we supplement comparisons with several advanced SAR detection methods, including transformer-based SMEP-DETR [53] and lightweight HLNet [54]. SMEP-DETR achieves a promising mAP by capturing global contextual information, but it lacks complete metric reports and involves heavy computation. By contrast, HLNet adopts a lightweight paradigm that is deliberately optimized for SAR ship detection, where targets exhibit relatively regular shapes and size distributions. This architectural choice inherently differs from our aircraft-oriented design, which must handle more diverse aspect ratios and finer category distinctions. Even though our CCS-Net is optimized for aircraft detection, it achieves a competitive mAP and higher precision compared with these state-of-the-art lightweight methods. Such satisfactory cross-category generalization further demonstrates the effectiveness and universality of the proposed SAR-specific optimization designs.
Nevertheless, both HRSID and SSDD remain constrained in terms of sensor variety and the diversity of imaging geometry. More comprehensive validation on a broader range of multi-sensor SAR datasets with richer imaging conditions will be explored in our future work.
5.5. Effectiveness Analysis of the CCS-Net
Ablation Study Analysis: To systematically validate the effectiveness of each proposed improvement module, we conducted comprehensive ablation studies on the SAR-Aircraft-1.0 dataset, with results presented in Table 8. We incrementally integrated the following components, analyzing performance under different combinations: CLAHE image enhancement, C2F_LK+MSCA feature extraction and fusion modules, the SCA-Head detection module, and the optimized loss function.
Table 8.
Ablation experiments (%) on CLAHE, C2F_LK, SCA-Head, and Improved Loss modules on the SAR-Aircraft-1.0 dataset. In this context, Improved Loss refers to BCELabelSmoothing.
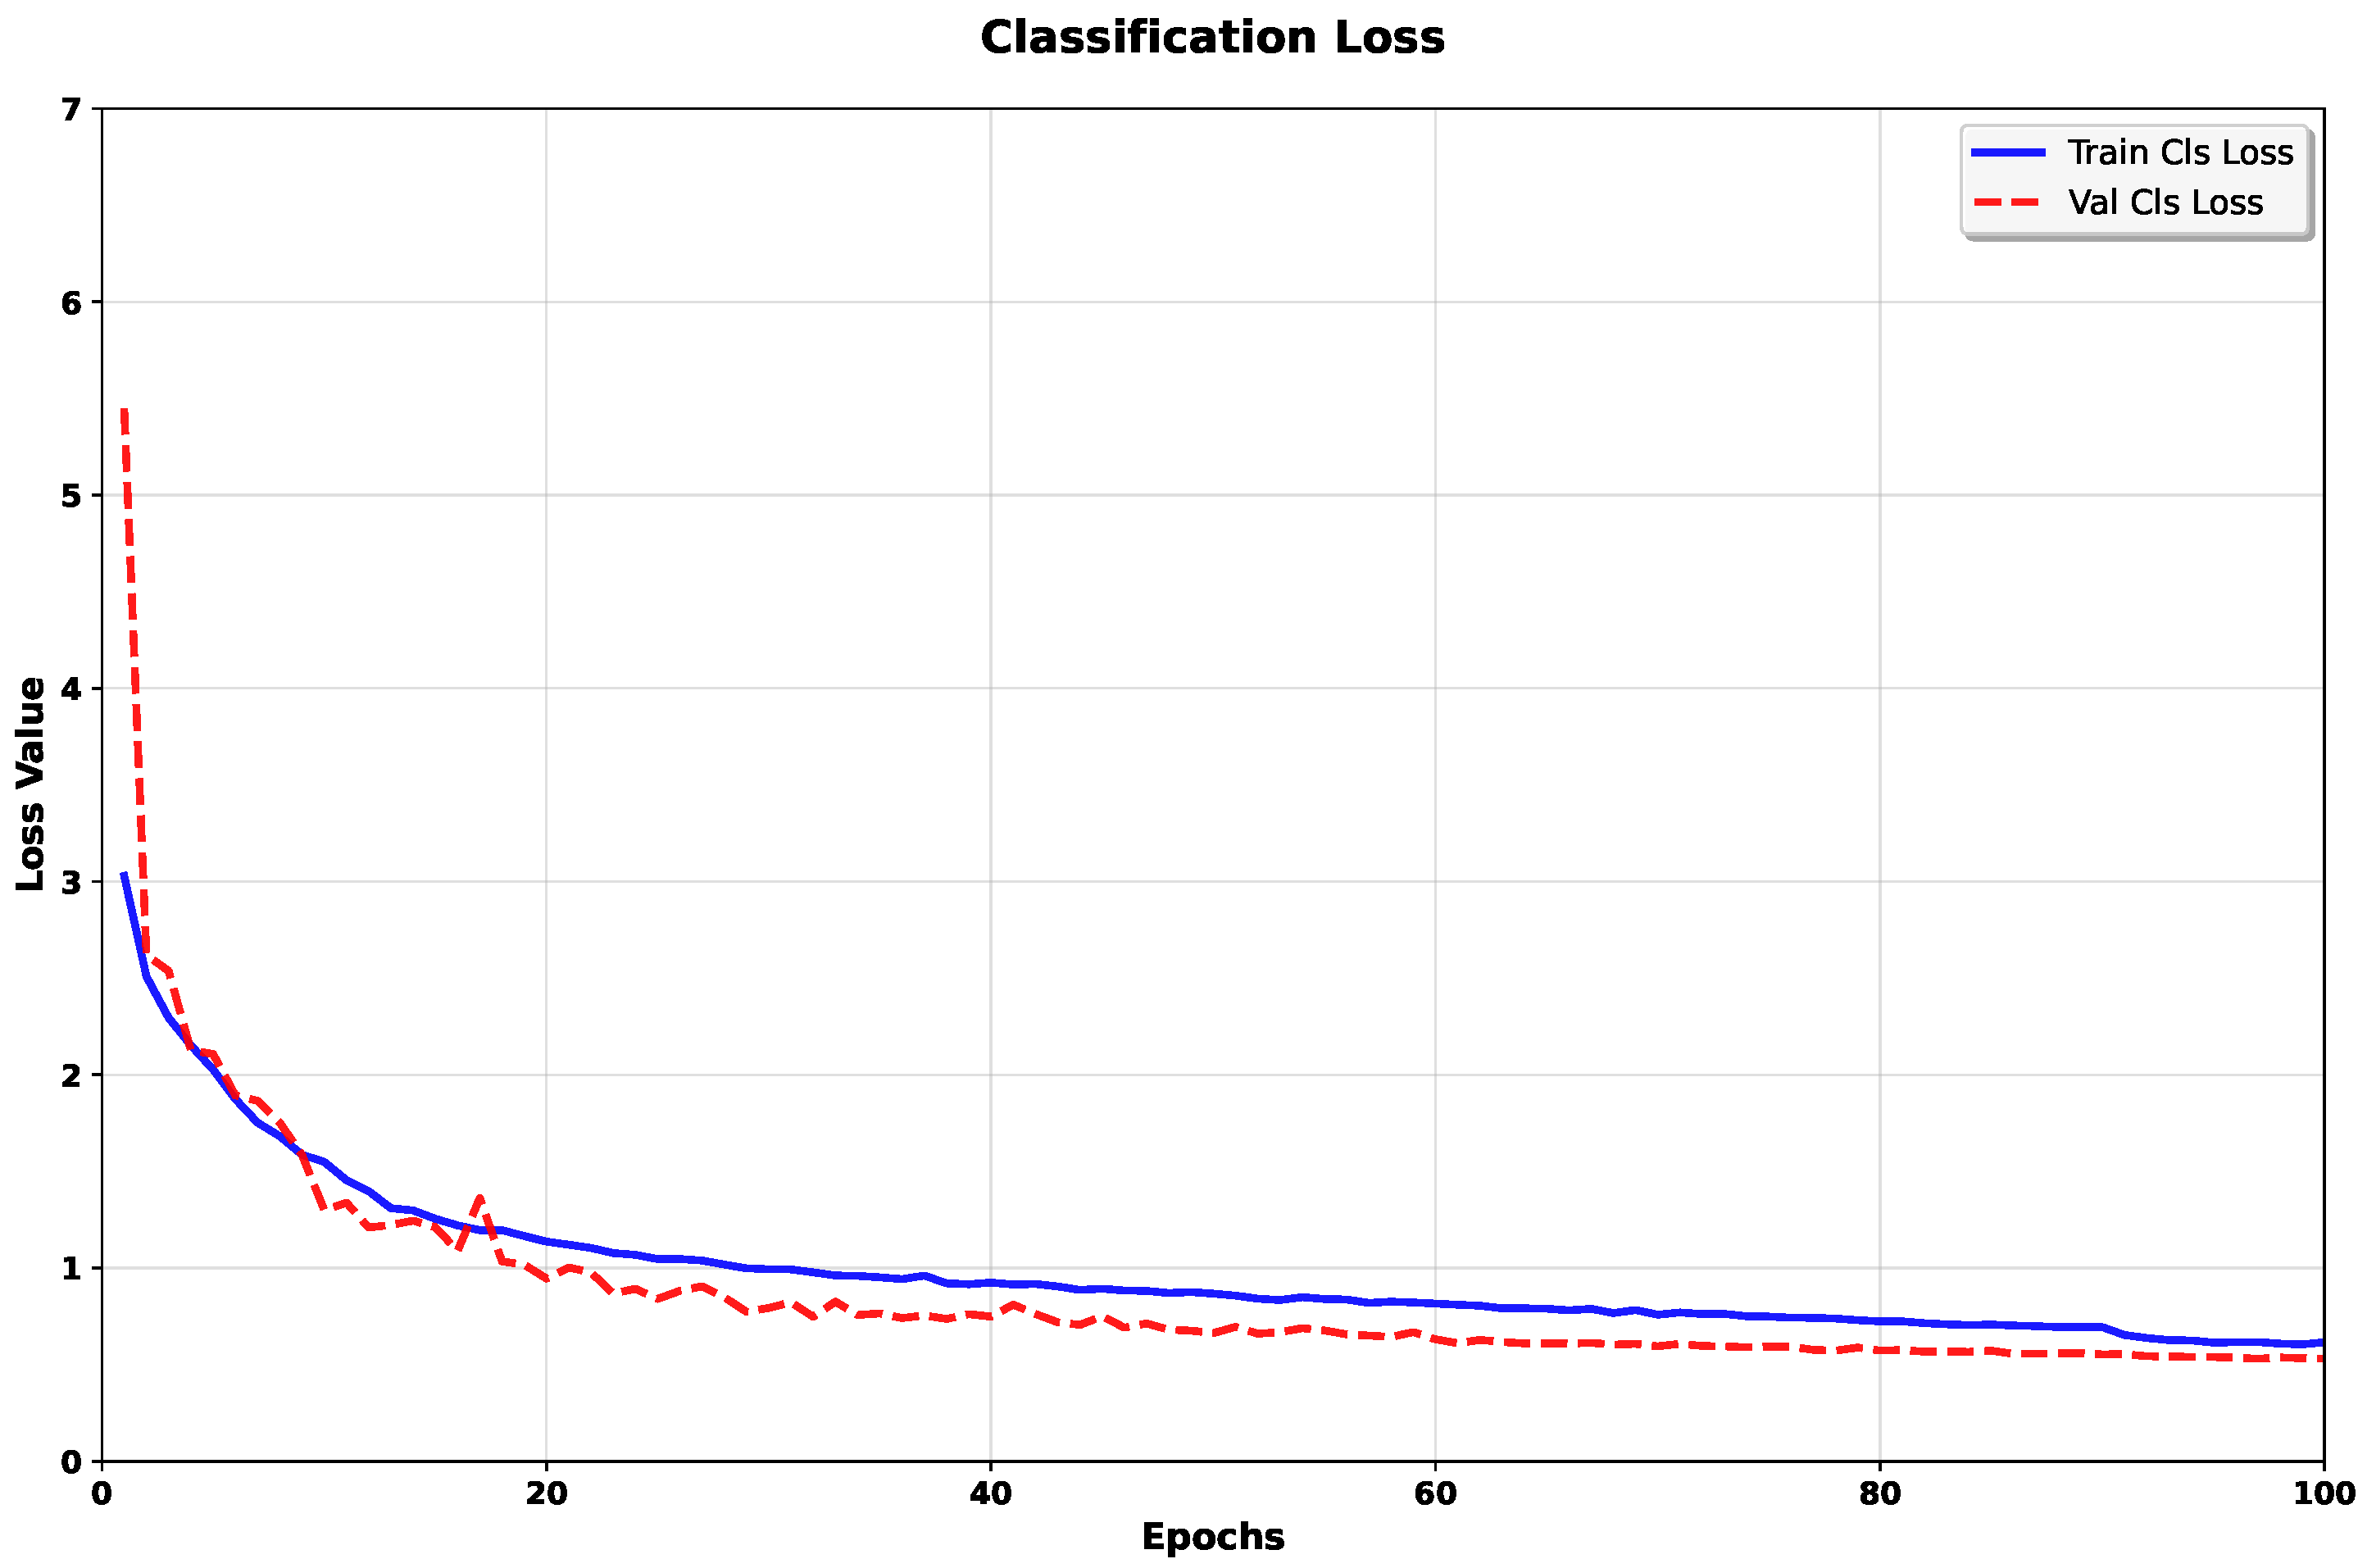
The experimental results demonstrate that each improvement module contributes positively to model performance. With the introduction of CLAHE preprocessing alone, mAP@0.5 increased from 94.6% to 95.0%, while mAP@0.75 showed significant improvement from 64.0% to 70.5%, indicating the crucial role of image enhancement in boosting localization accuracy. Independent integration of either the C2F_LK+MSCA module or the SCA-Head module also yielded performance gains, while the optimized loss function substantially enhanced classification precision and robustness, increasing precision from 86.6% to 90.6%. As shown in Figure 7, the model converged effectively when the BCE loss function was optimized using label-smoothing techniques.
Figure 7.
Illustration of the training and validation cls loss curves of the proposed CCS-Net framework on the SAR-Aircraft-1.0 dataset.
Regarding module combinations, both pairwise and multi-module integrations further optimized model performance. When all four improvement modules were combined, the model achieved optimal results across all metrics: precision of 93.5%, recall of 95.7%, mAP@0.5 of 96.6%, and mAP@0.75 of 73.8%, representing improvements of 6.9%, 4.2%, 2.0%, and 9.8%, respectively, over the baseline, fully validating the effectiveness of our proposed methods and the complementary nature between modules.
In conclusion, ablation studies confirm that each designed improvement module effectively enhances model performance for SAR aircraft target detection. Their combined utilization maximizes synergistic effects, significantly improving detection accuracy and localization capability while maintaining high recall rates.
Sensitivity Analysis of CLAHE’s Clip Limit: To explore how the clip-limit hyperparameter of CLAHE affects detection performance and to determine the optimal configuration for SAR aircraft enhancement, we conduct controlled comparative experiments on the SAR-Aircraft-1.0 dataset. Only the clip-limit value is adjusted, while all other network architectures and training settings remain fixed. The quantitative results are summarized in Table 9.
Table 9.
Sensitivity analysis (%) of the CLAHE clip limit on the SAR-Aircraft-1.0 dataset.
As shown in the table, the model achieves the highest precision, recall, mAP@0.5, and mAP@0.75 when the clip limit is set to 2.0. A smaller clip limit excessively suppresses local image contrast, weakening feature responses of small aircraft targets. When the clip limit exceeds 2.0, the enhancement operation will amplify inherent speckle clutter in SAR images, introducing background interference and reducing overall detection accuracy. Based on this sensitivity analysis, a clip limit of 2.0 is adopted as the fixed CLAHE configuration throughout the CCS-Net model.
Sensitivity Analysis of Dilation Rates in the MSCA Module: To explore the influence of multi-scale receptive fields arising from different dilation-rate combinations and determine the optimal configuration for multi-size SAR aircraft detection, we select four groups of typical dilation-rate combinations widely adopted in dilated convolution research for controlled experiments on the SAR-Aircraft-1.0 dataset. All network structures and hyperparameters are kept identical, except for the dilation rates inside the MSCA module, and the results of the quantitative comparison are summarized in Table 10.
Table 10.
Sensitivity analysis (%) of dilation rates in the MSCA module on the SAR Aircraft 1.0 dataset.
The (1,2) group yields insufficient receptive fields for large aircraft and low recall. The overly large (3,5) combination causes feature aliasing and worse small-target performance. The mismatched span of (2,5) leads to discontinuous multi-scale feature extraction. In contrast, (2,4) balances receptive-field coverage for small, medium, and large aircraft and achieves the best detection metrics. Thus, (2,4) is adopted for MSCA in the final CCS Net.
Sensitivity Analysis of the Label Smoothing Coefficient (): We test multiple coefficient values on SAR Aircraft 1.0 while keeping all other configurations fixed, and the results are given in Table 11. A coefficient of 0.0 corresponds to hard labels without smoothing and leads to model overconfidence. Excessively large coefficients over-smooth supervision signals and degrade detection accuracy. A value of 0.10 achieves the best balance of all metrics, so we adopt this setting in the loss function.
Table 11.
Sensitivity analysis (%) of the label smoothing coefficient () on the SAR Aircraft 1.0 dataset.
Attention-Module Comparison inside LarkBlock: We embed three typical attention modules—CBAM, coordinate attention, and SE—into LarkBlock for comparison experiments on SAR Aircraft 1.0. All other network configurations remain fixed, and results are shown in Table 12. CBAM introduces spatial attention but cannot adapt to multi-scale aircraft targets in SAR images. Coordinate attention, which embeds location cues, has limited feature enhancement capacity. Our optimized SE achieves the highest overall detection metrics, which verifies the superiority of the attention scheme adopted in this work.
Table 12.
Performance comparison of different attention modules inside LarkBlock on the SAR Aircraft 1.0 dataset.
5.6. Visualization Analysis
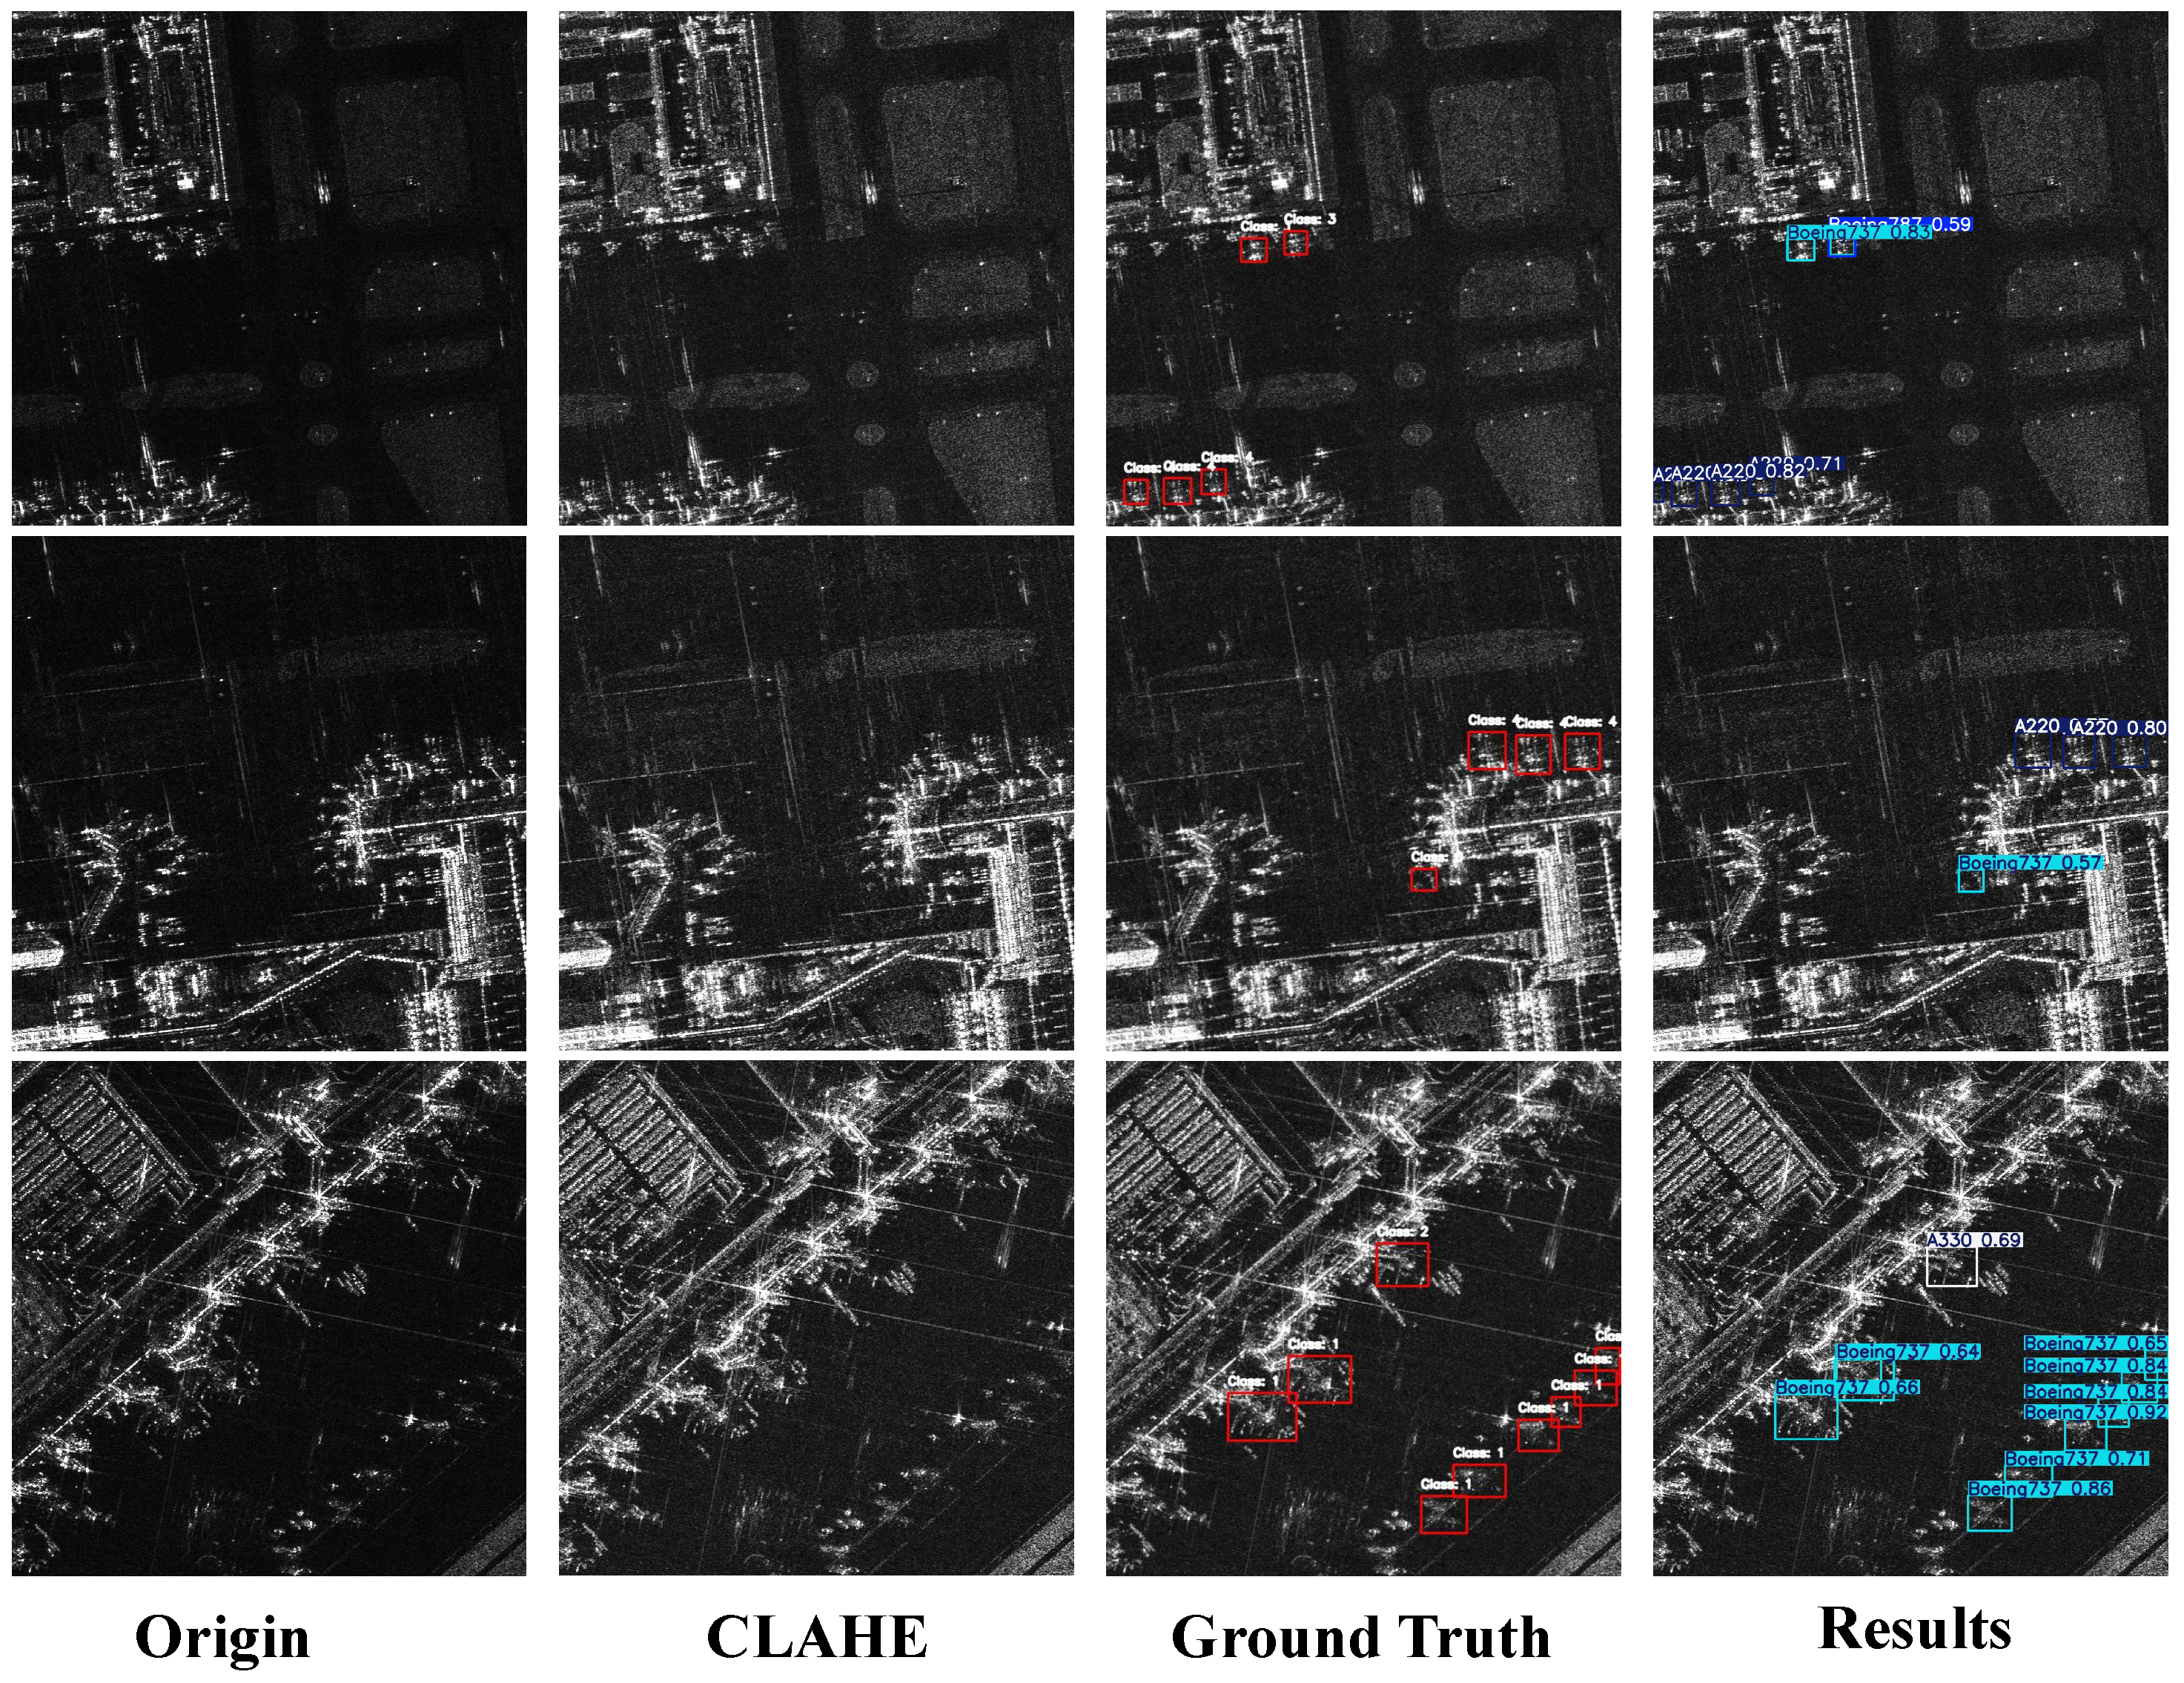
To qualitatively evaluate the detection performance of the proposed CCS-Net model, a comparative visualization is presented in Figure 8. The first column displays the raw SAR images, illustrating inherent challenges such as speckle noise and low intrinsic contrast. The second column shows the corresponding images enhanced by CLAHE, which mitigates these issues to some extent by improving local contrast.
Figure 8.
Aircraft detection in SAR images with the proposed CCS-Net model. The first column shows the raw SAR images from the SAR-Aircraft-1.0 dataset. The second column presents the CLAHE-enhanced images. The third column displays the ground truth, where manually annotated aircraft regions are marked with bounding boxes. The last column demonstrates the detection results of CCS-Net.
A comparison between the model’s predictions and the ground-truth annotations reveals a high degree of spatial alignment. The CCS-Net-generated bounding boxes closely encompass aircraft targets, with high associated confidence scores, indicating robust identification and precise localization. In particular, the model maintains this performance across aircraft of varying scales and under different background complexities, as evidenced in the figure. Additional insights into the model’s behavior are obtained by examining its performance under difficult SAR scene conditions. Five representative challenging conditions are considered: closely spaced aircraft, tiny targets, images with severe speckle noise, partially occluded aircraft, and cluttered-background scenes. Our CCS-Net achieves stable performance for closely spaced aircraft, heavy speckle noise, and cluttered backgrounds. However, it still suffers from limited detection accuracy for tiny targets and partially occluded aircraft, which remains a key limitation to be addressed in future work.
These visual outcomes corroborate the quantitative results, suggesting that the multi-scale context aggregation architecture of CCS-Net is effective in extracting discriminative features from challenging SAR imagery. The model demonstrates a strong capability to suppress false positives in cluttered backgrounds while preserving high sensitivity for true aircraft targets, underscoring its potential for practical application in SAR-based aerial target detection.
6. Conclusions
This paper introduces CCS-Net, a pioneering multi-scale feature learning framework designed for aircraft target detection in SAR imagery. The proposed model achieves enhanced detection accuracy and operational efficiency through an integrated multi-stage architecture with the following key contributions: (1) CLAHE preprocessing is employed to mitigate speckle noise interference and enhance contrast in SAR images. (2) The C2F_LK and MSCA modules are designed to extract discriminative multi-scale features. (3) An FPN-PAN architecture is utilized to effectively fuse features across different scales. (4) The dedicated SCA-Head module enhances detection capability for small-scale targets through spatial and coordinate attention mechanisms. (5) The label-smoothing technique is introduced to optimize the loss function, addressing both category imbalance and overfitting issues.
Extensive evaluation on the SAR-Aircraft-1.0 and SADD datasets demonstrates the superior performance of our method, achieving 96.6% mAP@0.5 with only 0.97 M parameters on SAR-Aircraft-1.0 and 97.7% mAP@0.5 on SADD, thereby showing significant improvement over existing approaches. Cross-domain tests on the HRSID and SSDD ship benchmarks further validate its strong generalization across different SAR target categories. The framework demonstrates noteworthy generalization capabilities, as evidenced by comprehensive ablation studies and visual analysis, thereby substantiating its interpretability and robustness in complex scenes.
In summary, while maintaining a low parameter count, the proposed method significantly improves aircraft detection performance in SAR imagery, offering substantial practical deployment value and providing reliable technical support for automated remote sensing interpretation systems. Despite the above advantages, CCS-Net still has inherent limitations: it exhibits limited scalability for ultra-large SAR datasets and struggles with multi-class and dense multi-object detection, and its performance remains vulnerable to harsh imaging interferences, including heavy speckle noise and cluttered backgrounds. Future work will explore the model’s capability in detecting small and densely clustered targets in complex scenarios; investigate its generalization across different sensors and imaging modes; and further introduce self-supervised learning, multimodal fusion, and foundation model embedding to boost the model’s feature representation and overall robustness.
Author Contributions
L.B.: Funding Acquisition, Supervision, and Writing—Review and Editing. D.L.: Conceptualization, Methodology, Investigation, Formal Analysis, and Writing—Original Draft. C.L. and X.G.: Data Curation, and Writing—Review and Editing. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the National Natural Science Foundation of China (Grant 660 No. 12502325) and National University of Defense Technology Independent Innovation 661 Scientific Fund (Grant No. ZK24-62, ZK24-63).
Informed Consent Statement
This article is licensed under the Creative Commons Attribution 4.0 International License. Based on the terms of this license, the Licensed Material can be copied and shared in whole or in part. Additionally, adapted material can be created, copied, and shared. This license is free, non-transferable, non-exclusive, and irrevocable and applies worldwide. The hyperlink to access the licensed material is https://creativecommons.org/licenses/by/4.0/ (accessed on 10 May 2026).
Data Availability Statement
The data that support the findings of this study are available from the corresponding author upon reasonable request.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Rizaev, I.G.; Karakuş, O.; Hogan, S.J.; Achim, A. Modeling and SAR imaging of the sea surface: A review of the state-of-the-art with simulations. ISPRS J. Photogramm. Remote Sens. 2022, 187, 120–140. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Lai, Y.; Ma, J.; Feng, C.; Shu, J. A video-based prediction algorithm for armored vehicle and aircraft detection/tracking and trajectory. Acta Armamentarii 2021, 42, 545. [Google Scholar]
- Asiyabi, R.M.; Ghorbanian, A.; Tameh, S.N.; Amani, M.; Jin, S.; Mohammadzadeh, A. Synthetic aperture radar (SAR) for ocean: A review. IEEE J. Sel. Top. Appl. Earth Obs. Remote Sens. 2023, 16, 9106–9138. [Google Scholar] [CrossRef] [Scilit]
- Hm, F. Adaptive detection mode with threshold control as a function of spatially sampled clutter-level estimates. Rca Rev. 1968, 29, 414–465. [Google Scholar]
- Kuttikkad, S.; Chellappa, R. Non-Gaussian CFAR techniques for target detection in high resolution SAR images. In Proceedings of the 1st International Conference on Image Processing; IEEE: New York, NY, USA, 1994; Volume 1, pp. 910–914. [Google Scholar]
- Song, Y.; Lou, J.; Jin, T. A novel II-CFAR detector for ROI extraction in SAR image. In Proceedings of the 2013 IEEE International Conference on Signal Processing, Communication and Computing (ICSPCC 2013); IEEE: New York, NY, USA, 2013; pp. 1–4. [Google Scholar]
- Chen, X.; Sun, J.; Yin, K.; Yu, J.u. A cascade CFAR-based ship target detection algorithm for SAR images. Mod. Radar 2012, 34, 50–54. [Google Scholar]
- Pisner, D.A.; Schnyer, D.M. Support vector machine. In Machine Learning; Academic Press: Cambridge, MA, USA, 2020; pp. 101–121. [Google Scholar]
- Breiman, L. Random forests. In Machine Learning; Academic Press: Cambridge, MA, USA, 2001; Volume 45, pp. 5–32. [Google Scholar]
- Brown, W.M. Synthetic aperture radar. IEEE Trans. Aerosp. Electron. Syst. 1967, AES-3, 217–229. [Google Scholar] [CrossRef] [Scilit]
- Girshick, R. Fast r-cnn. In Proceedings of the IEEE International Conference on Computer Vision; IEEE: New York, NY, USA, 2015; pp. 1440–1448. [Google Scholar]
- Ren, S.; He, K.; Girshick, R.; Sun, J. Faster R-CNN: Towards real-time object detection with region proposal networks. IEEE Trans. Pattern Anal. Mach. Intell. 2016, 39, 1137–1149. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Liu, W.; Anguelov, D.; Erhan, D.; Szegedy, C.; Reed, S.; Fu, C.Y.; Berg, A.C. Ssd: Single shot multibox detector. In Proceedings of the European Conference on Computer Vision; Springer: Berlin/Heidelberg, Germany, 2016; pp. 21–37. [Google Scholar]
- Redmon, J.; Divvala, S.; Girshick, R.; Farhadi, A. You only look once: Unified, real-time object detection. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition; IEEE: New York, NY, USA, 2016; pp. 779–788. [Google Scholar]
- Wu, K.; Zhang, Z.; Chen, Z.; Liu, G. Object-enhanced YOLO networks for synthetic aperture radar ship detection. Remote Sens. 2024, 16, 1001. [Google Scholar] [CrossRef] [Scilit]
- Nichol, A.; Dhariwal, P.; Ramesh, A.; Shyam, P.; Mishkin, P.; McGrew, B.; Sutskever, I.; Chen, M. Glide: Towards photorealistic image generation and editing with text-guided diffusion models. arXiv 2021, arXiv:2112.10741. [Google Scholar]
- Shao, W.; Rajapaksha, P.; Wei, Y.; Li, D.; Crespi, N.; Luo, Z. COVAD: Content-oriented video anomaly detection using a self attention-based deep learning model. Virtual Real. Intell. Hardw. 2023, 5, 24–41. [Google Scholar] [CrossRef] [Scilit]
- Chang, H.; Fu, X.; Dong, J.; Liu, J.; Zhou, Z. MLSDNet: Multiclass lightweight SAR detection network based on adaptive scale distribution attention. IEEE Geosci. Remote Sens. Lett. 2023, 20, 4010305. [Google Scholar] [CrossRef] [Scilit]
- Juan, S.; Long, Y.; Hua, H.; Guodong, J. Improved SSD algorithm for small ship target detection in SAR images. Syst. Eng. Electron. 2020, 42, 1026–1034. [Google Scholar]
- Guo, Q.; Wang, H.; Xu, F. Scattering enhanced attention pyramid network for aircraft detection in SAR images. IEEE Trans. Geosci. Remote Sens. 2020, 59, 7570–7587. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Hu, D.; Li, S.; Luo, Y.; Li, J.; Zhang, C. Aircraft detection from low SCNR SAR imagery using coherent scattering enhancement and fused attention pyramid. Remote Sens. 2023, 15, 4480. [Google Scholar] [CrossRef] [Scilit]
- Wen, Y.; Wang, Y.; Wang, H.; Shi, W.; Cao, W. Co-salient object detection with iterative purification and predictive optimization. Virtual Real. Intell. Hardw. 2024, 6, 396–407. [Google Scholar] [CrossRef] [Scilit]
- Yang, S.; An, W.; Li, S.; Zhang, S.; Zou, B. An inshore SAR ship detection method based on ghost feature extraction and cross-scale interaction. IEEE Geosci. Remote Sens. Lett. 2023, 20, 3507305. [Google Scholar] [CrossRef] [Scilit]
- Zhang, J.; Ke, F.; Tang, Q.; Yu, W.; Zhang, M. YGC-SLAM: A visual SLAM based on improved YOLOv5 and geometric constraints for dynamic indoor environments. Virtual Real. Intell. Hardw. 2025, 7, 62–82. [Google Scholar] [CrossRef] [Scilit]
- Li, G.; Su, J.; Li, Y. Aircraft Detection in SAR Images Based on Improved Faster R-CNN. J. Beijing Univ. Aeronaut. Astronaut. 2021, 47, 159–168. [Google Scholar]
- Lin, T.Y.; Goyal, P.; Girshick, R.; He, K.; Dollár, P. Focal loss for dense object detection. In Proceedings of the IEEE International Conference on Computer Vision; IEEE: New York, NY, USA, 2017; pp. 2980–2988. [Google Scholar]
- Xiao, X.; Jia, H.; Xiao, P.; Wang, H. Aircraft detection in SAR images based on peak feature fusion and adaptive deformable network. Remote Sens. 2022, 14, 6077. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Xiao, H.; Chen, L.; Xing, J.; Pan, Z.; Luo, R.; Cai, X. Integrating weighted feature fusion and the spatial attention module with convolutional neural networks for automatic aircraft detection from SAR images. Remote Sens. 2021, 13, 910. [Google Scholar] [CrossRef] [Scilit]
- Li, K.; Wang, D.; Hu, Z.; Zhu, W.; Li, S.; Wang, Q. Unleashing channel potential: Space-frequency selection convolution for SAR object detection. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition; IEEE: New York, NY, USA, 2024; pp. 17323–17332. [Google Scholar]
- Ge, Z.; Liu, S.; Wang, F.; Li, Z.; Sun, J. Yolox: Exceeding yolo series in 2021. arXiv 2021, arXiv:2107.08430. [Google Scholar]
- Zhirui, W.; Yuzhuo, K.; Xuan, Z.; Yuelei, W.; Ting, Z.; Xian, S. SAR-AIRcraft-1.0: A high-resolution SAR aircraft detection and recognition dataset. J. Radars 2023, 12, 906–922. [Google Scholar]
- Sharma, R.; Kamra, A. A review on CLAHE based enhancement techniques. In Proceedings of the 2023 6th International Conference on Contemporary Computing and Informatics (IC3I); IEEE: New York, NY, USA, 2023; Volume 6, pp. 321–325. [Google Scholar]
- Hu, J.; Shen, L.; Sun, G. Squeeze-and-excitation networks. In Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition; IEEE: New York, NY, USA, 2018; pp. 7132–7141. [Google Scholar]
- Zhang, Y.; Ye, M.; Zhu, G.; Liu, Y.; Guo, P.; Yan, J. FFCA-YOLO for Small Object Detection in Remote Sensing Images. IEEE Trans. Geosci. Remote Sens. 2024, 62, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Müller, R.; Kornblith, S.; Hinton, G.E. When does label smoothing help? Adv. Neural Inf. Process. Syst. 2019, 32, 4696–4705. [Google Scholar]
- Zhang, P.; Xu, H.; Tian, T.; Gao, P.; Li, L.; Zhao, T.; Zhang, N.; Tian, J. SEFEPNet: Scale expansion and feature enhancement pyramid network for SAR aircraft detection with small sample dataset. IEEE J. Sel. Top. Appl. Earth Obs. Remote Sens. 2022, 15, 3365–3375. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Wang, C.; Zhang, H.; Dong, Y.; Wei, S. A SAR dataset of ship detection for deep learning under complex backgrounds. Remote Sens. 2019, 11, 765. [Google Scholar] [CrossRef] [Scilit]
- Zhang, T.; Zhang, X.; Li, J.; Xu, X.; Wang, B.; Zhan, X.; Xu, Y.; Ke, X.; Zeng, T.; Su, H.; et al. SAR ship detection dataset (SSDD): Official release and comprehensive data analysis. Remote Sens. 2021, 13, 3690. [Google Scholar] [CrossRef] [Scilit]
- Chen, J.; Shen, Y.; Liang, Y.; Wang, Z.; Zhang, Q. Yolo-sad: An efficient SAR aircraft detection network. Appl. Sci. 2024, 14, 3025. [Google Scholar] [CrossRef] [Scilit]
- Zhou, Q.; Pan, Z.; Niu, B. SFEF-Net: Scattering Feature Extraction and Fusion Network for Aircraft Detection in SAR Images. Sensors 2025, 25, 2988. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhou, J.; Xiao, C.; Peng, B.; Liu, Z.; Liu, L.; Liu, Y.; Li, X. DiffDet4SAR: Diffusion-based aircraft target detection network for SAR images. IEEE Geosci. Remote Sens. Lett. 2024, 21, 1–5. [Google Scholar] [CrossRef] [Scilit]
- Zhou, J.; Liu, Y.; Peng, B.; Liu, L.; Li, X. MaDiNet: Mamba Diffusion Network for SAR Target Detection. IEEE Trans. Circuits Syst. Video Technol. 2025, 35, 10787–10800. [Google Scholar] [CrossRef] [Scilit]
- Guo, X.; Xu, B. SAR-NTV-YOLOv8: A neural network aircraft detection method in SAR images based on despeckling preprocessing. Remote Sens. 2024, 16, 3420. [Google Scholar] [CrossRef] [Scilit]
- Li, W.; Yang, W.; Hou, Y.; Liu, L.; Liu, Y.; Li, X. SARATR-X: Towards building a foundation model for SAR target recognition. IEEE Trans. Image Process. 2025, 34, 869–884. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhou, F.; Yang, T.; Tan, L.; Xu, X.; Xing, M. DAP-Net: Enhancing SAR target recognition with dual-channel attention and polarimetric features. Vis. Comput. 2025, 41, 7641–7656. [Google Scholar] [CrossRef] [Scilit]
- Junos, M.H.; Khairuddin, A.S.M. YOLO-MMS for aerial object detection model based on hybrid feature extractor and improved multi-scale prediction. Vis. Comput. 2025, 41, 4759–4778. [Google Scholar] [CrossRef] [Scilit]
- Lan, D.; Wang, Z.; Guo, Y.; Du, Y.; Yan, J. Adaptive region proposal selection for SAR target detection using reinforcement learning. J. Radars 2022, 11, 884–896. [Google Scholar]
- Yang, Y.; Lei, Z.; Mo, X.; Lu, D.; Jia, H.; Wang, H. SARDet-CL: Self-Supervised Contrastive Learning with Feature Enhancement and Imaging Mechanism Constraints for SAR Target Detection. IEEE Trans. Geosci. Remote Sens. 2025, 63, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Zhang, H.; Yu, H.; Tao, Y.; Zhu, W.; Zhang, K. Improvement of ship target detection algorithm for YOLOv7-tiny. IET Image Process. 2024, 18, 1710–1718. [Google Scholar] [CrossRef] [Scilit]
- Yao, Y.; Qiao, G.; Zhang, S.; Wu, C.; Wu, Z.; Cheng, T.; Zheng, H. Research on Morphometric Methods for Larimichthys crocea Based on YOLOv11-CBAM X-Ray Imaging. Fishes 2025, 10, 641. [Google Scholar] [CrossRef] [Scilit]
- Shen, Y.; Gao, Q. Ds-yolo: A SAR ship detection model for dense small targets. Radioengineering 2025, 34, 407–421. [Google Scholar] [CrossRef] [Scilit]
- Wang, Z.; Li, W.; Fan, Y.; Wang, L.; Yao, G. Ship target detection algorithm in remote sensing images based on improved YOLO11s. Ocean. Eng. 2026, 343, 123204. [Google Scholar] [CrossRef] [Scilit]
- Yu, C.; Shin, Y. SMEP-DETR: Transformer-based ship detection for SAR imagery with multi-edge enhancement and parallel dilated convolutions. Remote Sens. 2025, 17, 953. [Google Scholar] [CrossRef] [Scilit]
- Guo, X.; Deng, F.; Gong, J.; Zhang, J.; Guo, J.; Wang, Y.; Zeng, Y.; Li, G. HLNet: A Lightweight Network for Ship Detection in Complex SAR Environments. Remote Sens. 2026, 18, 577. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.