Evaluating the X2000: A Novel Integrated Platform for Rapid ADAS Development


Abstract
1. Introduction
- Nvidia DRIVE developer kit;
- Baidu Apollo;
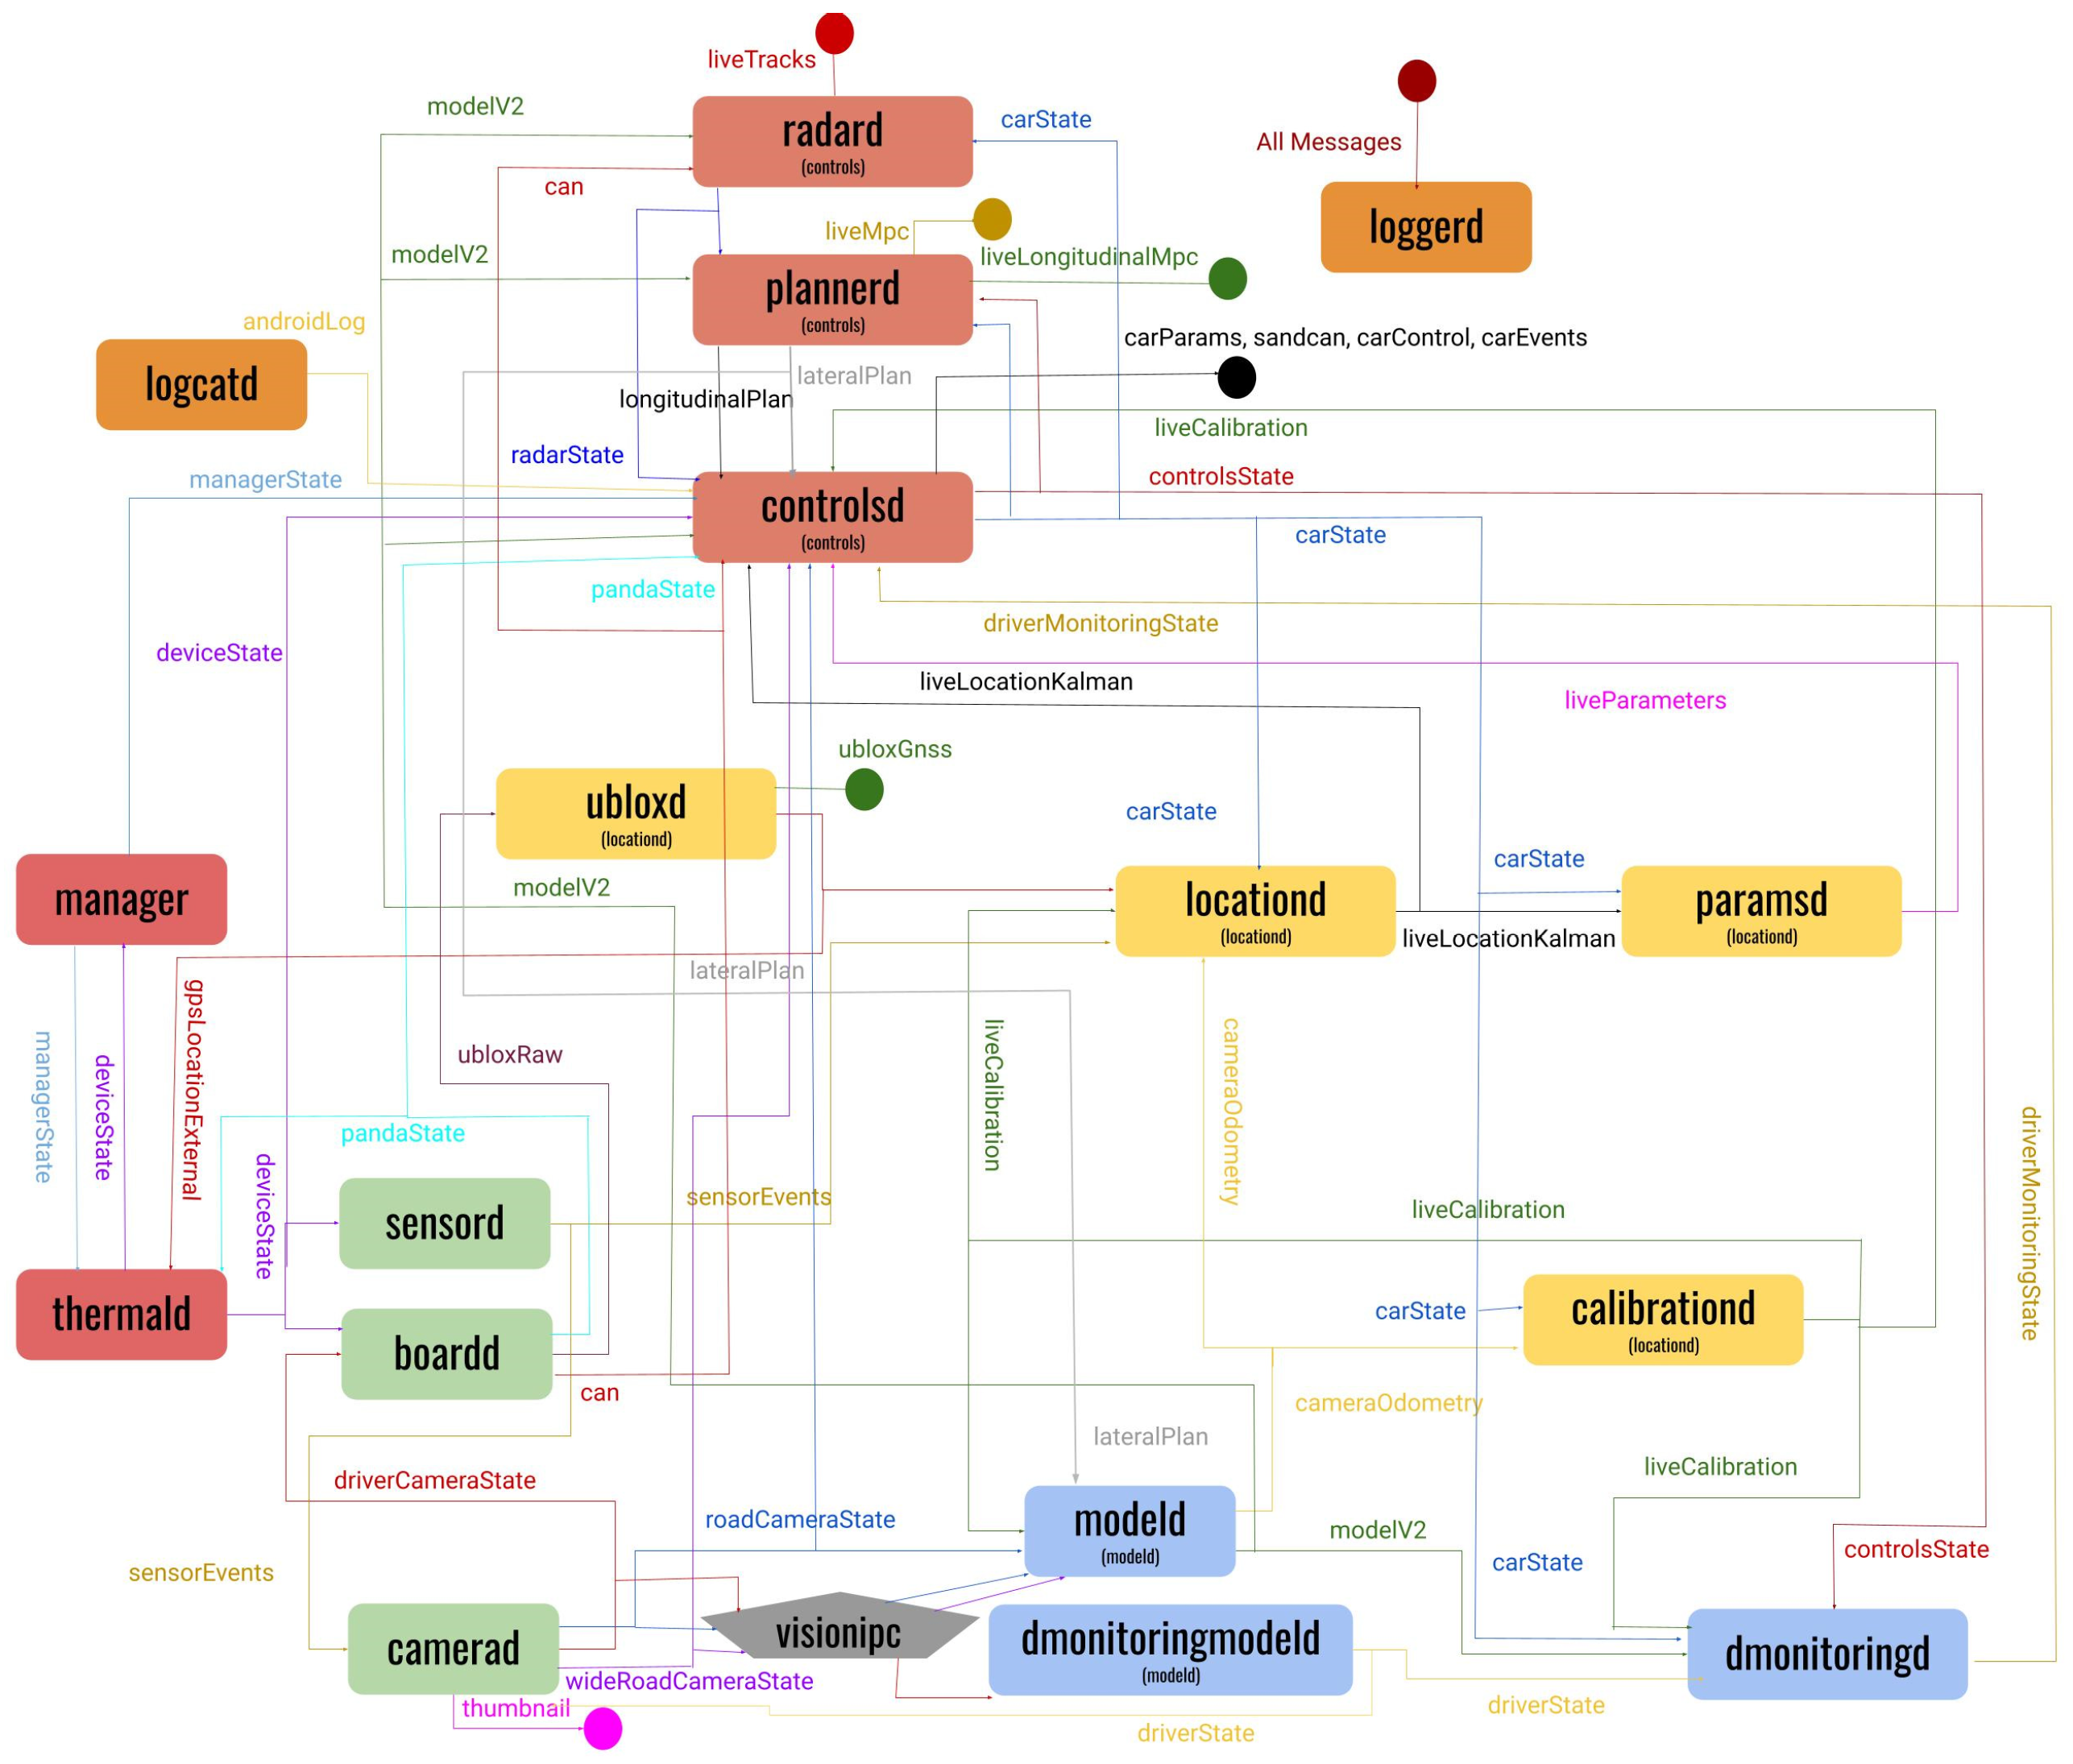
- Comma.ai Comma Four running Openpilot.
2. Materials and Methods
2.1. Software Reference Design
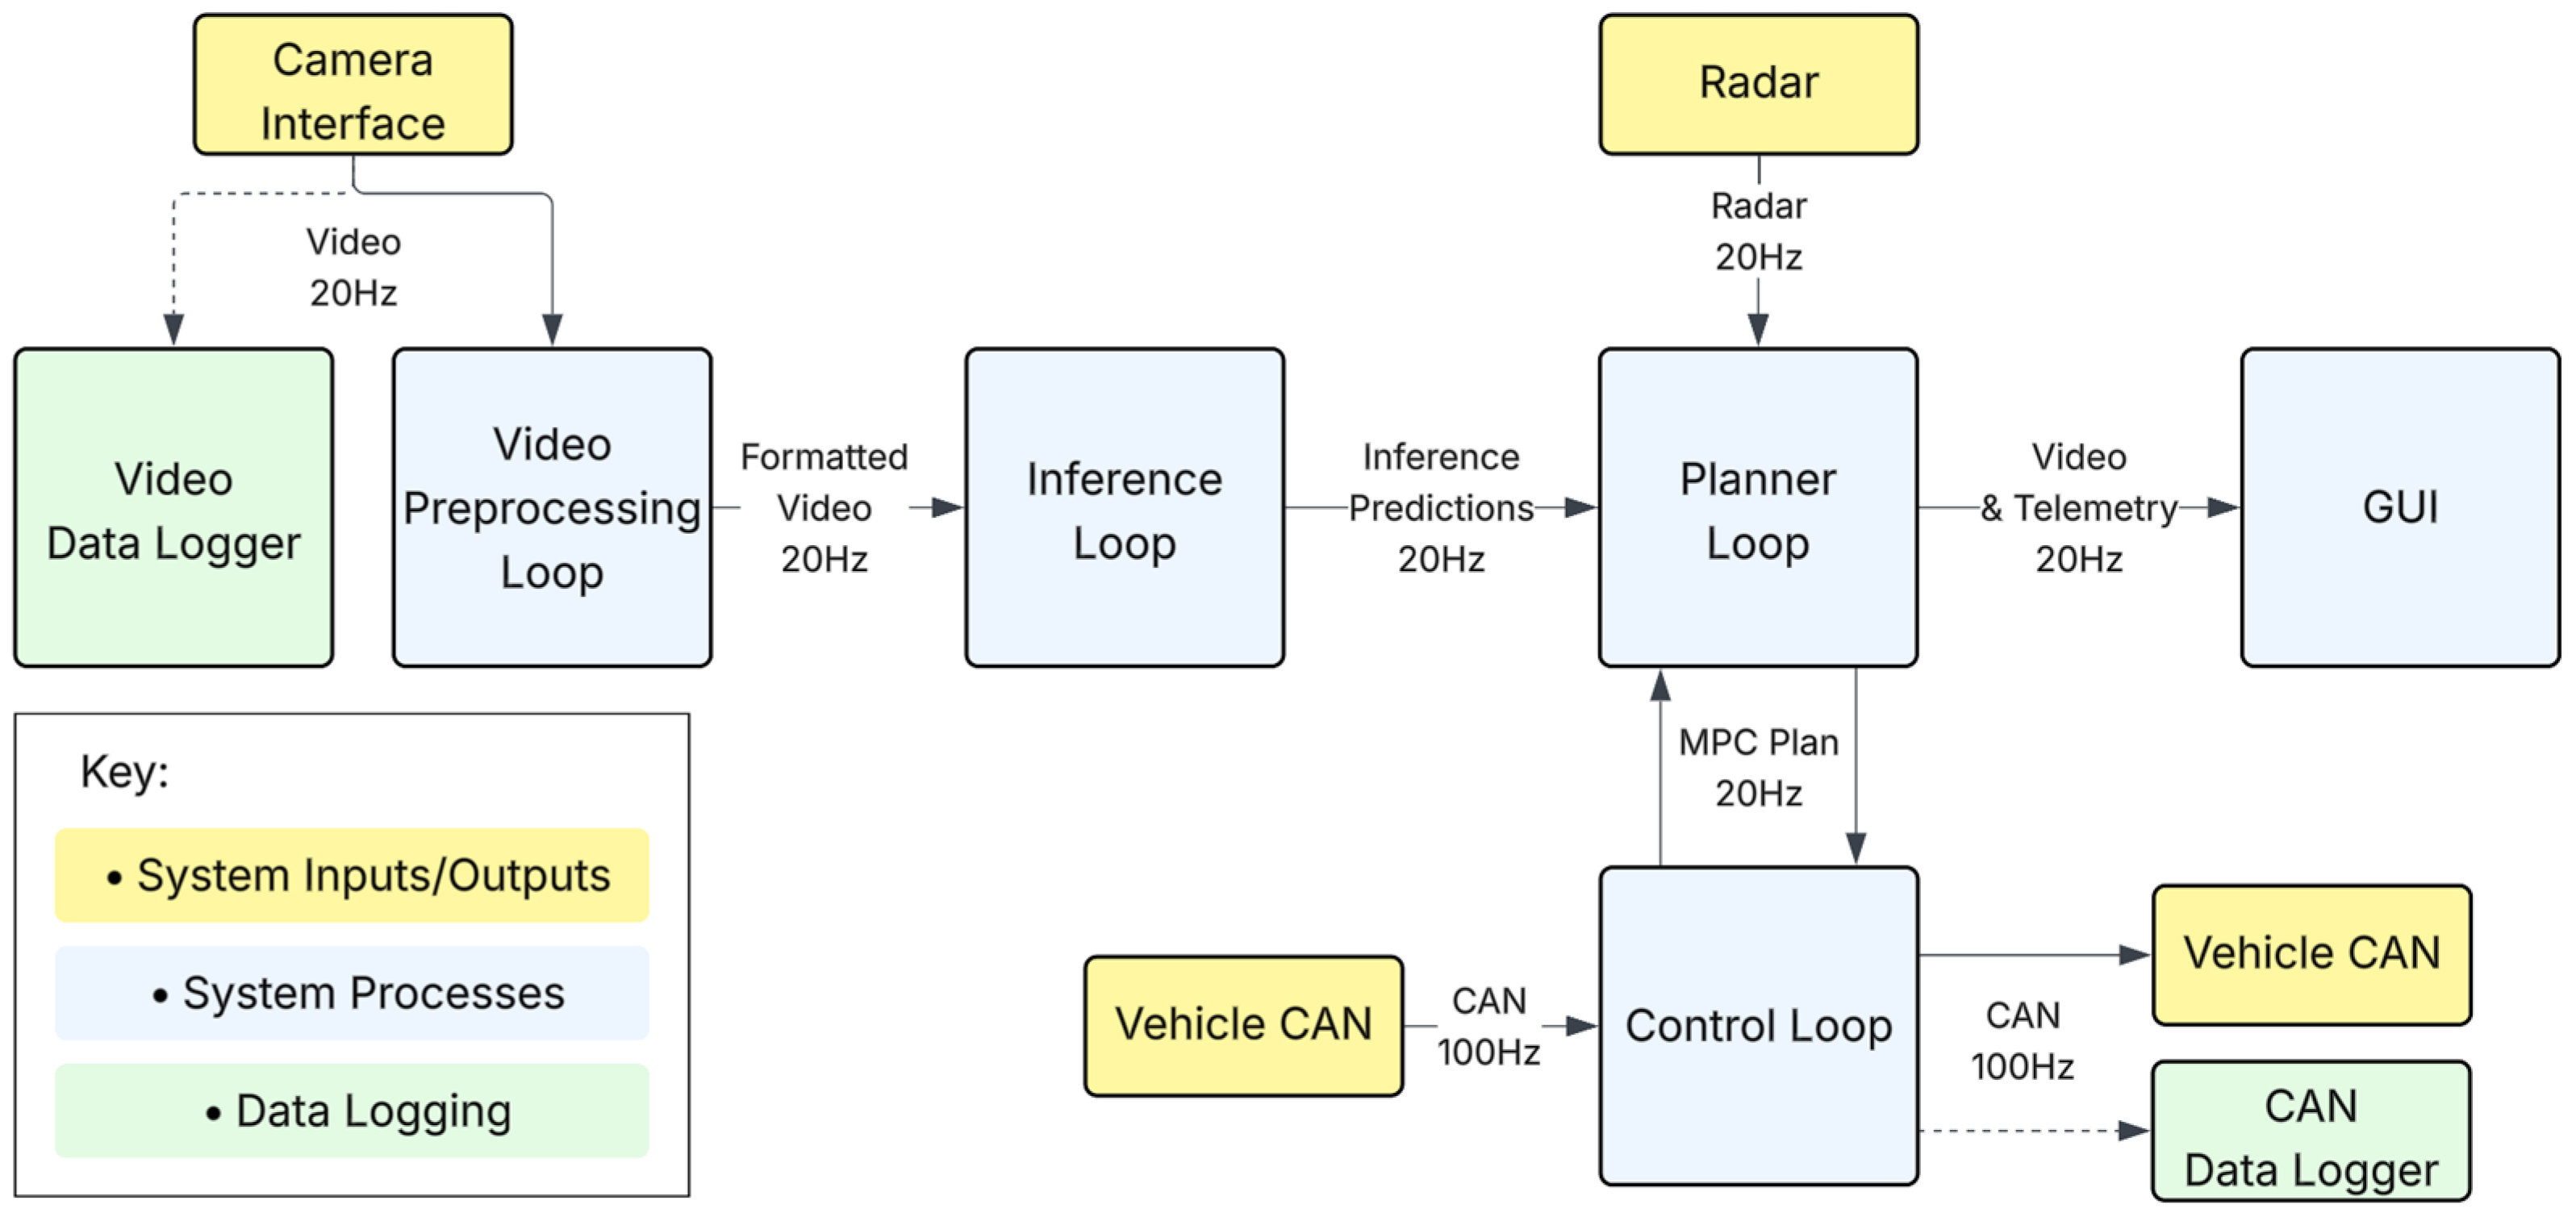
- Preparing video frames for inference at 20 Hz;
- Performing computer vision inference at 20 Hz;
- Calculating vehicle control plans from inference outputs, vehicle state data, and radar using a model predictive control (MPC) algorithm at 20 Hz;
- Processing CAN-FD inputs and outputs to execute control plans at 100 Hz;
- Formatting live camera, inference, and control data to be displayed on the vehicle’s center console screen at 20 Hz;
- Logging video and CAN-FD data while driving at 20 Hz and 100 Hz, respectively.
2.2. Extensibility
- Five seconds of one-hot encoded desired actions at 100 Hz with shape (100, 8);
- A one-hot encoded indicator for left or right-handed traffic with shape (2);
- Speed and steering delays with shape (2);
- A feature buffer for the last five seconds of feature data at 20 Hz with shape (100, 512) [18].
- Initialize the sensor connection and class attributes;
- Read data from the sensor and process it based on vehicle calibration requirements;
- Write data to the sensor (if applicable);
- Update the sensor’s class attributes with the data being collected.
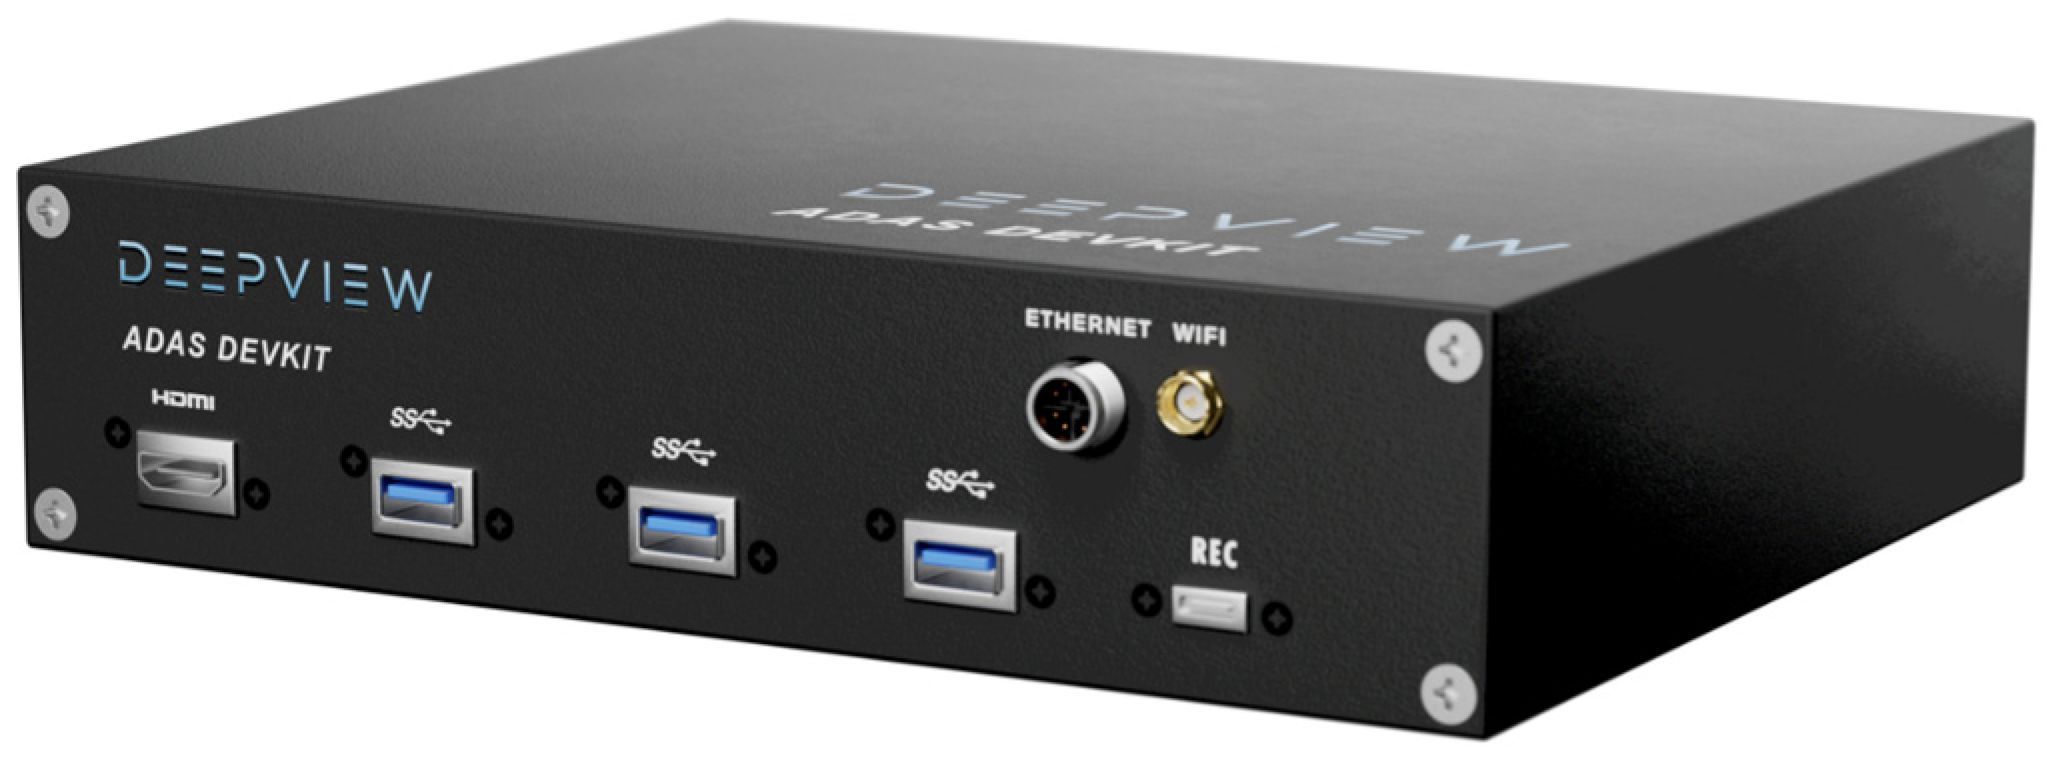
2.3. AI Compute Hardware
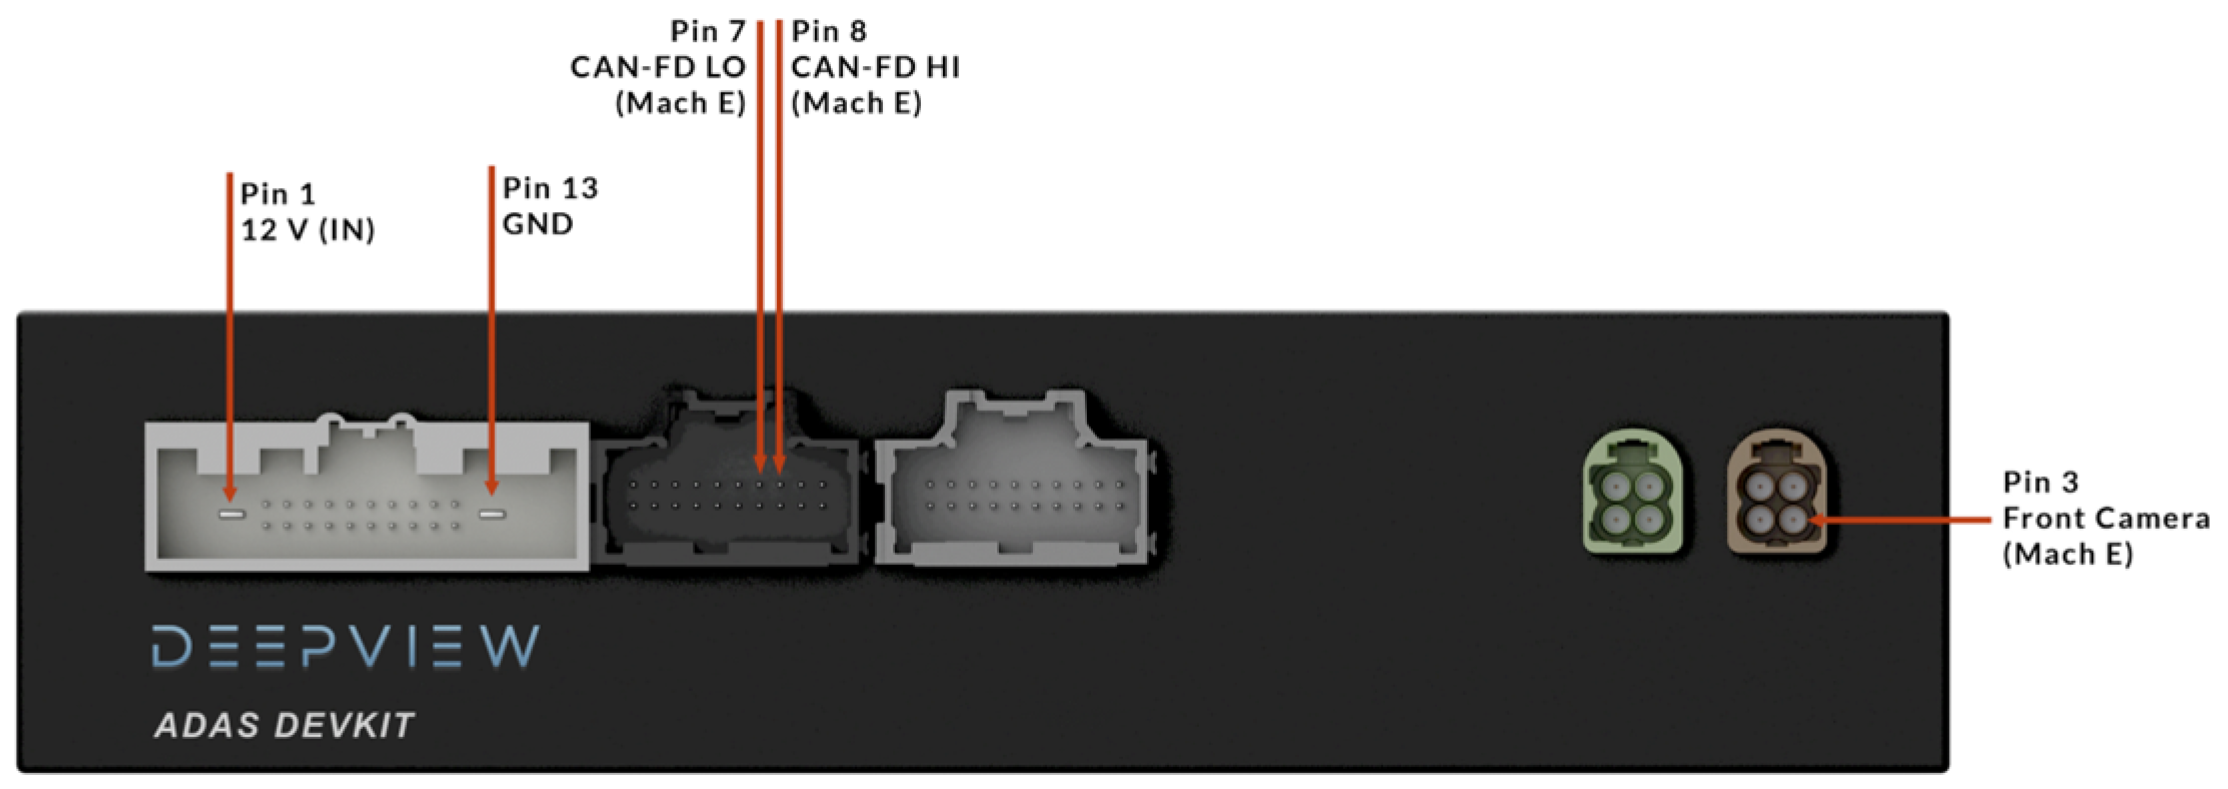
2.4. CAN-FD Interface
2.5. Throttle-by-Wire & Brake-by-Wire Control
- Total braking acceleration requested in m/s2;
- Acceleration requested in m/s2;
- Cruise control enabled or disabled;
- Allow resuming cruise control;
- Active deceleration request;
- Stop state request.
2.6. Electronic Power-Assisted Steering (EPAS) Control
- The vehicle’s target offset from the center of the lane in meters;
- The offset angle from the vehicle’s path in radians;
- The curvature the vehicle should follow in inverse meters (1/m);
- The rate of change of that curvature in inverse meters squared (1/m2);
- Enabling or disabling lateral control;
- How closely the vehicle should follow the given curvature;
- If the driver’s hands are on the wheel for safety.
2.7. GMSL2 Camera
2.8. Safety
3. Results
3.1. Introduction
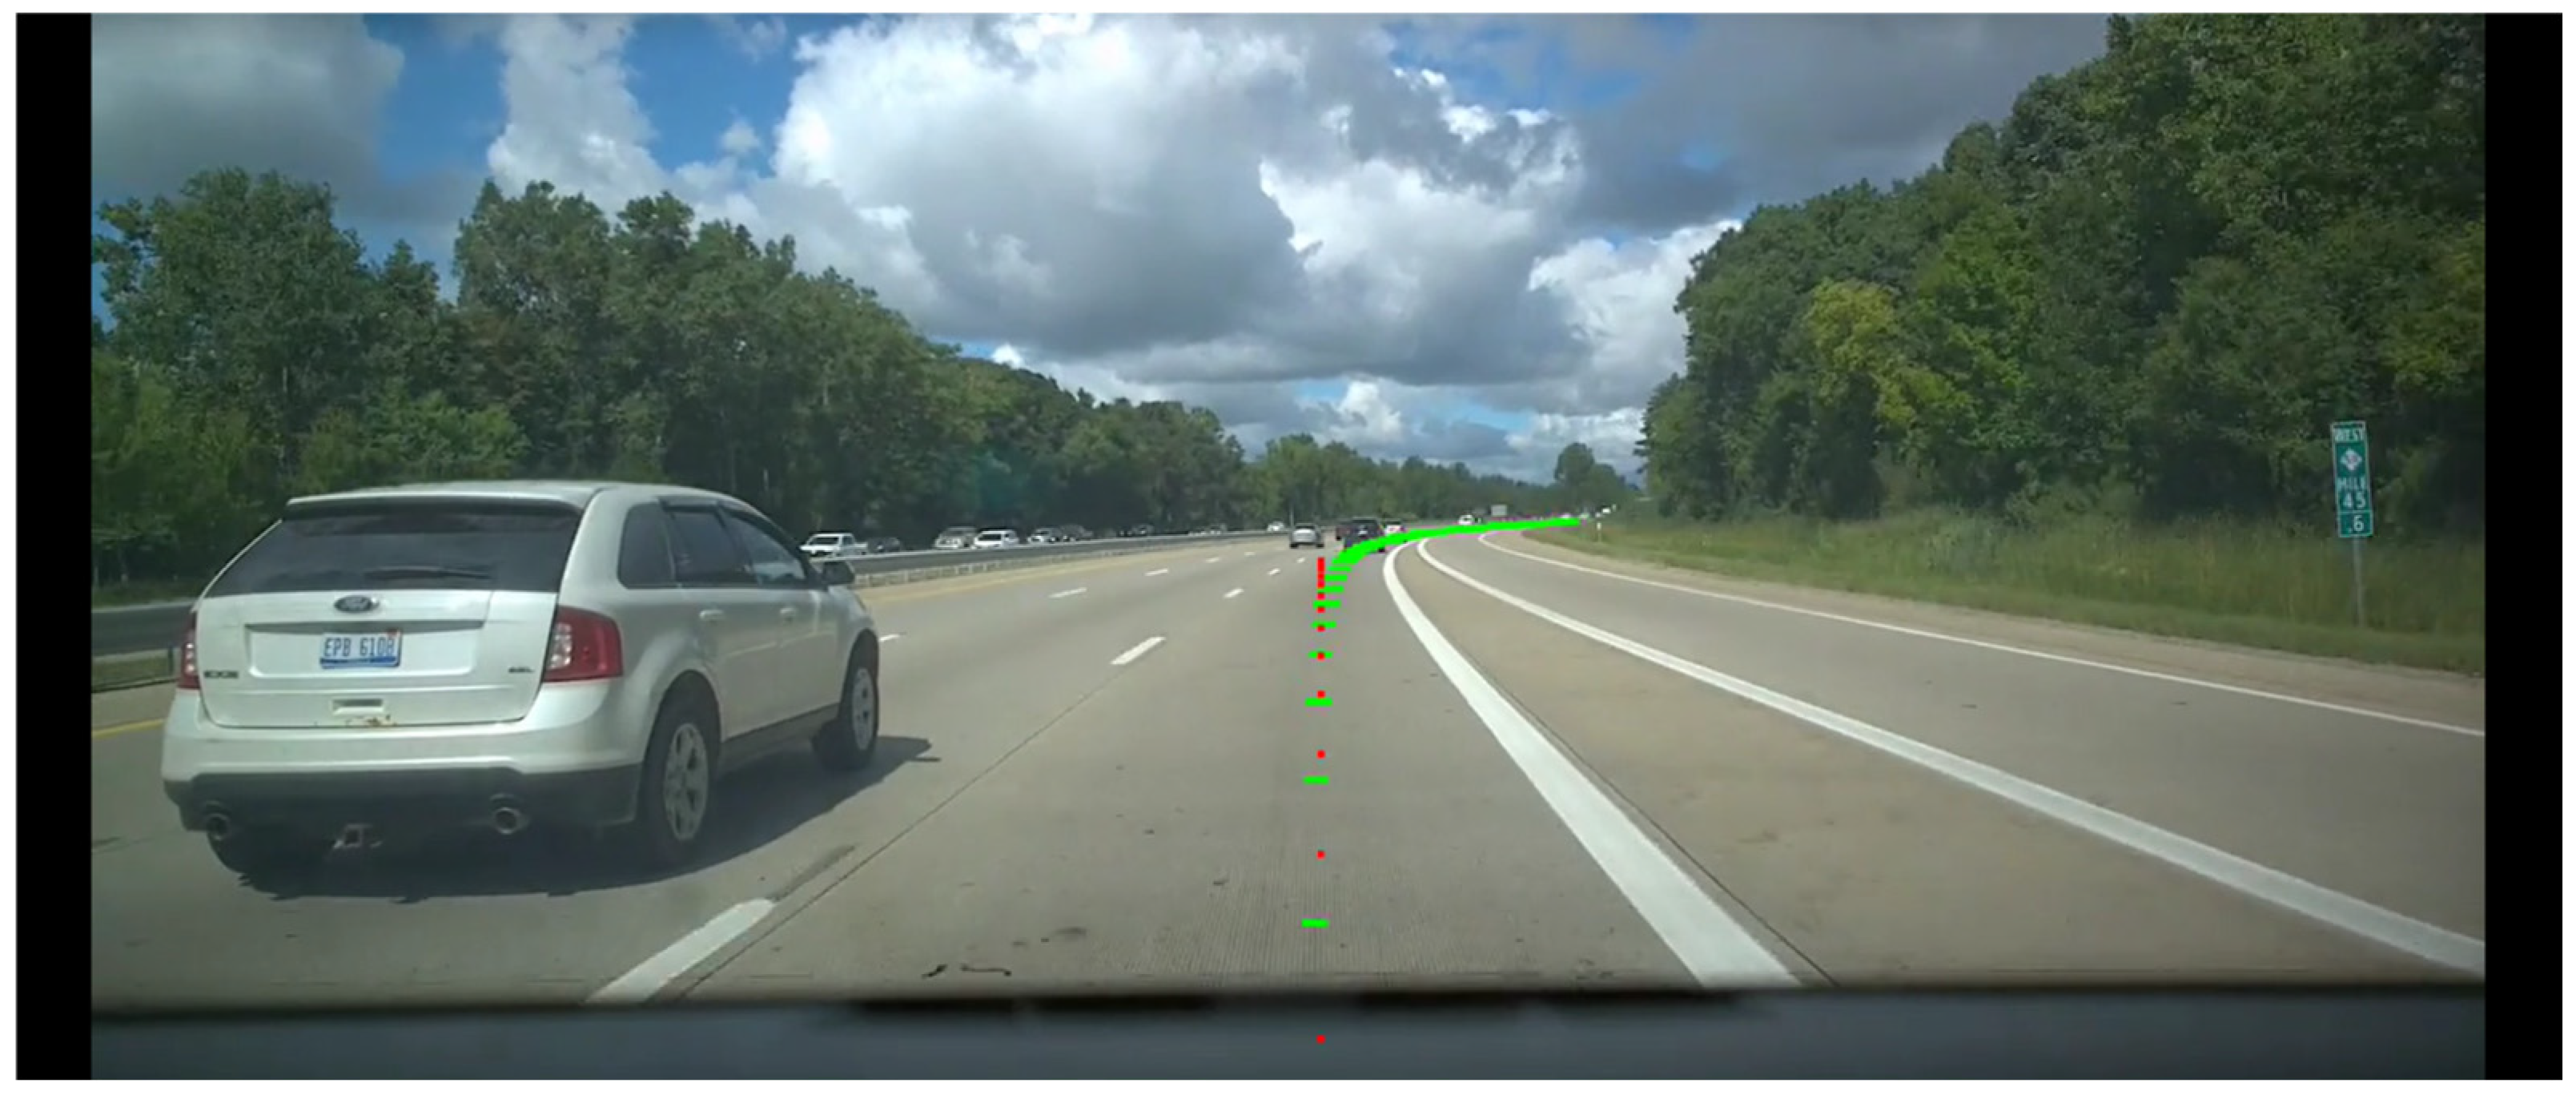
- Length: 20 min;
- Environment: Daytime, United States Interstate Highway;
- Traffic Density: Medium/Low;
- Weather: Partly Cloudy;
- Number of Routes: 1.
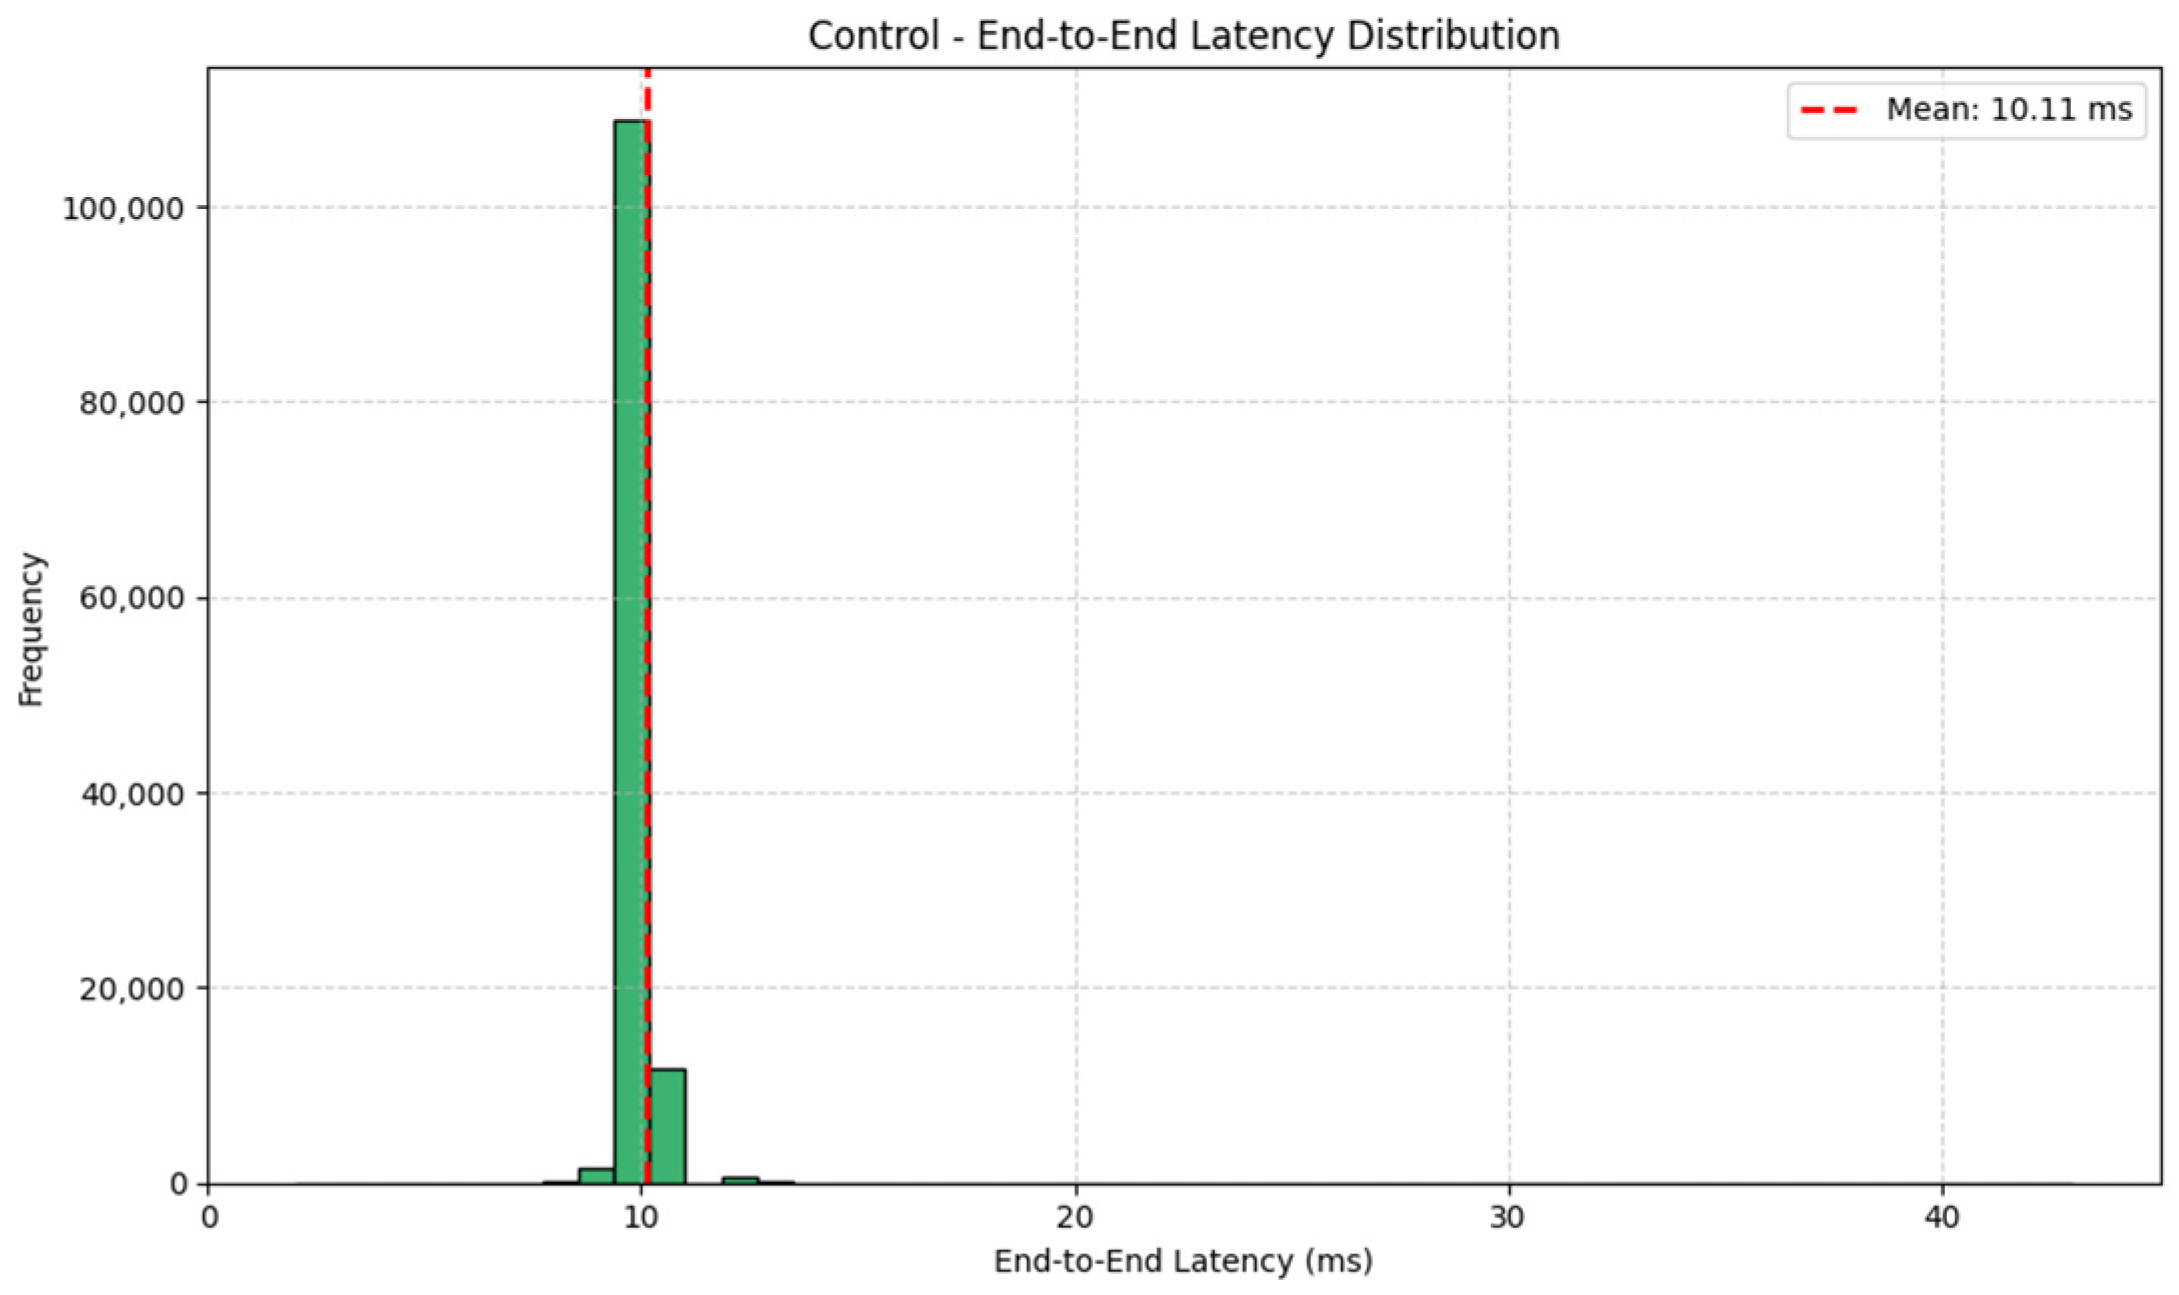
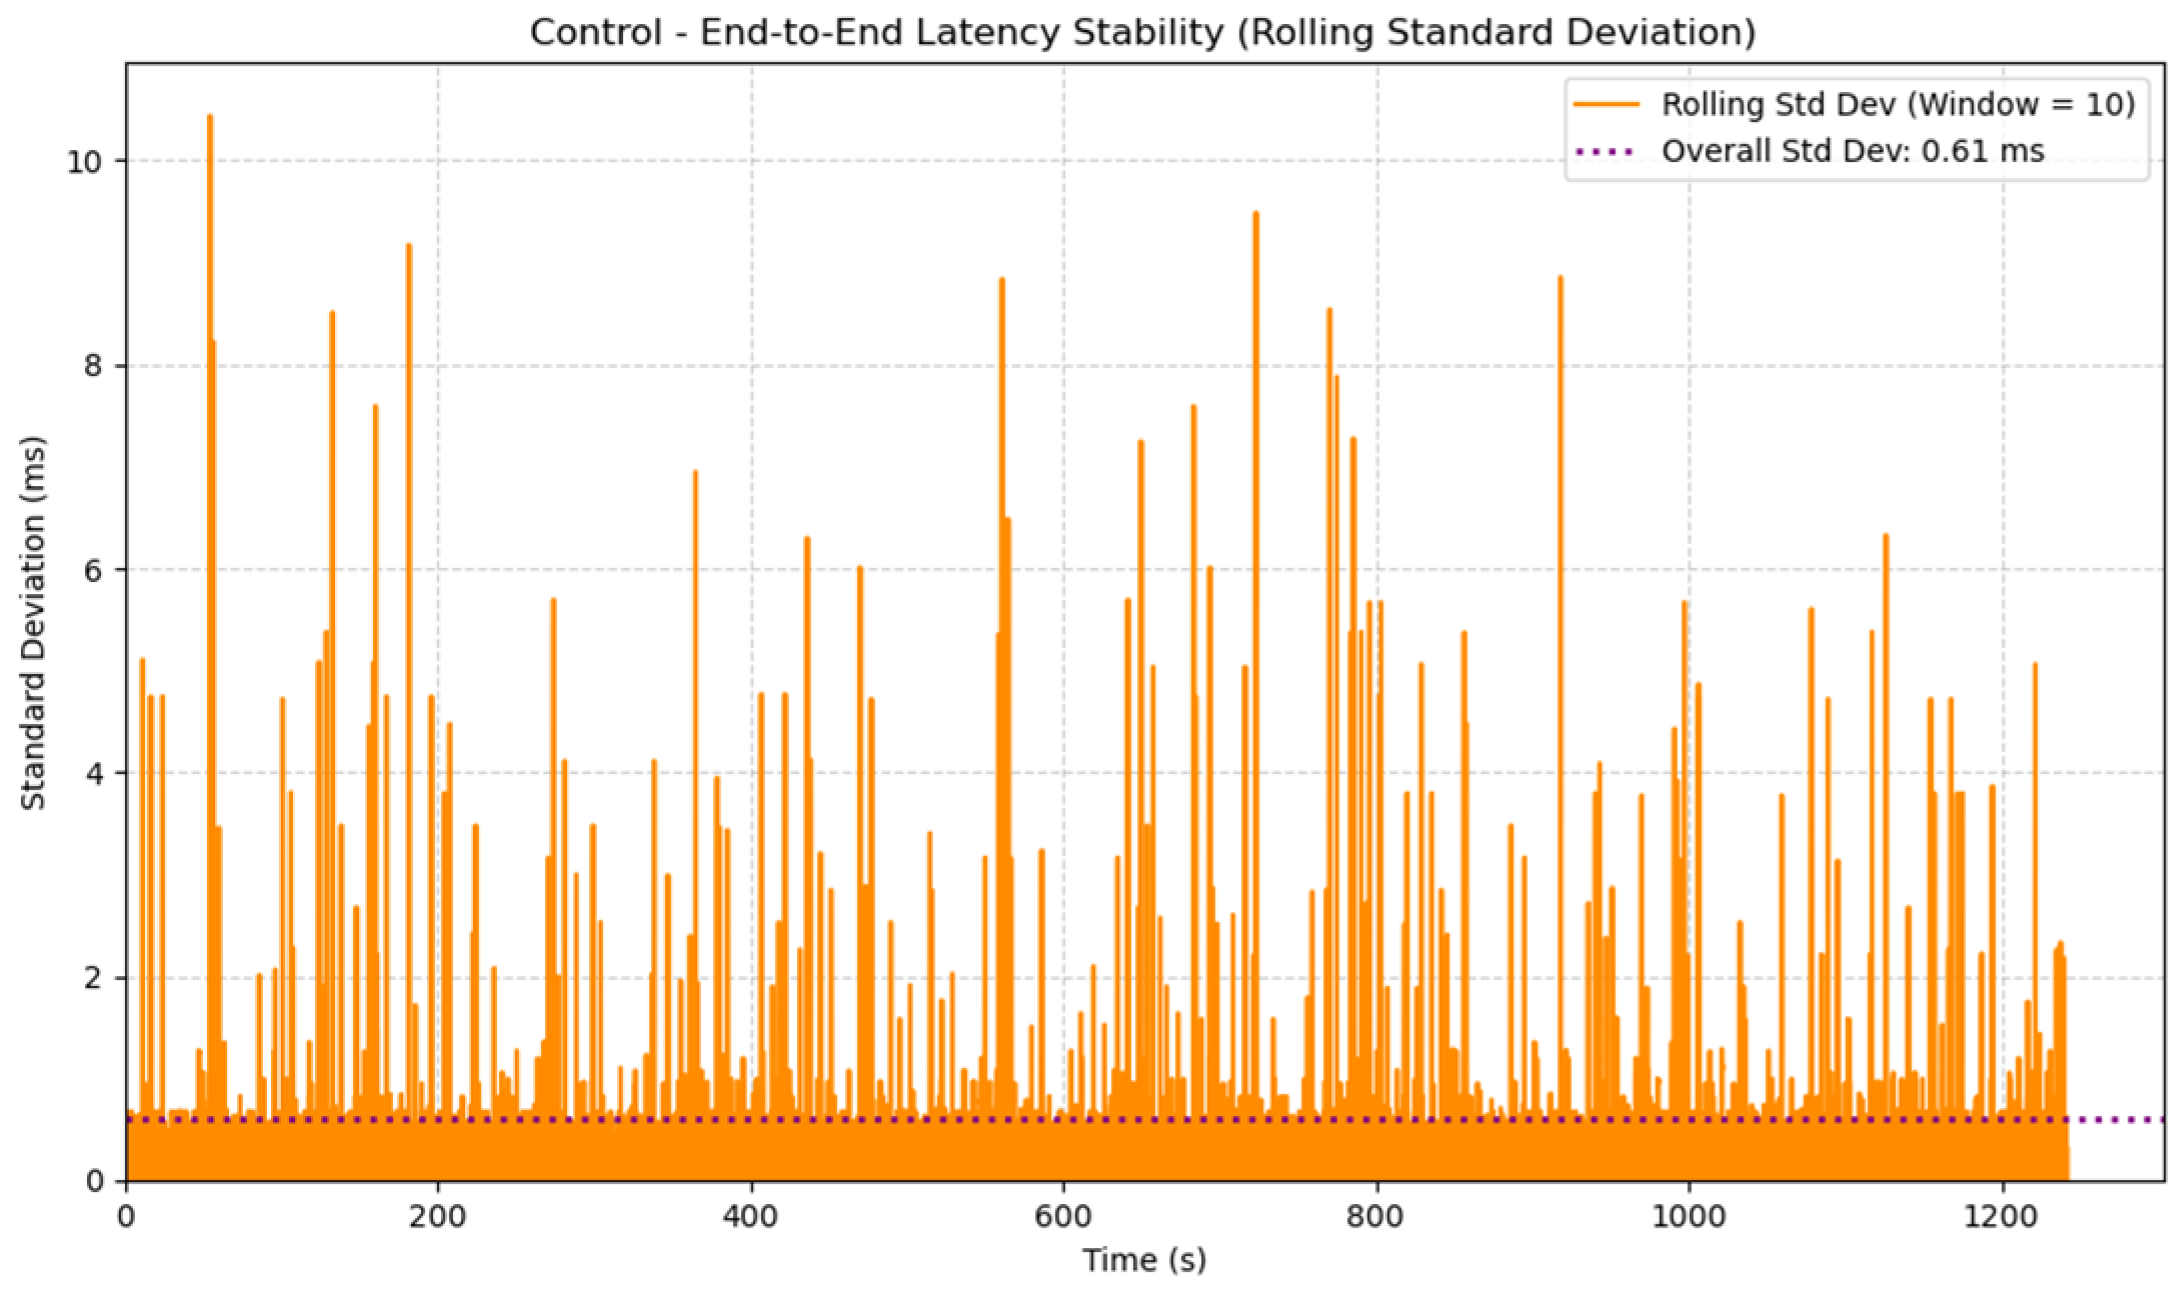
3.2. Control End-to-End Latency
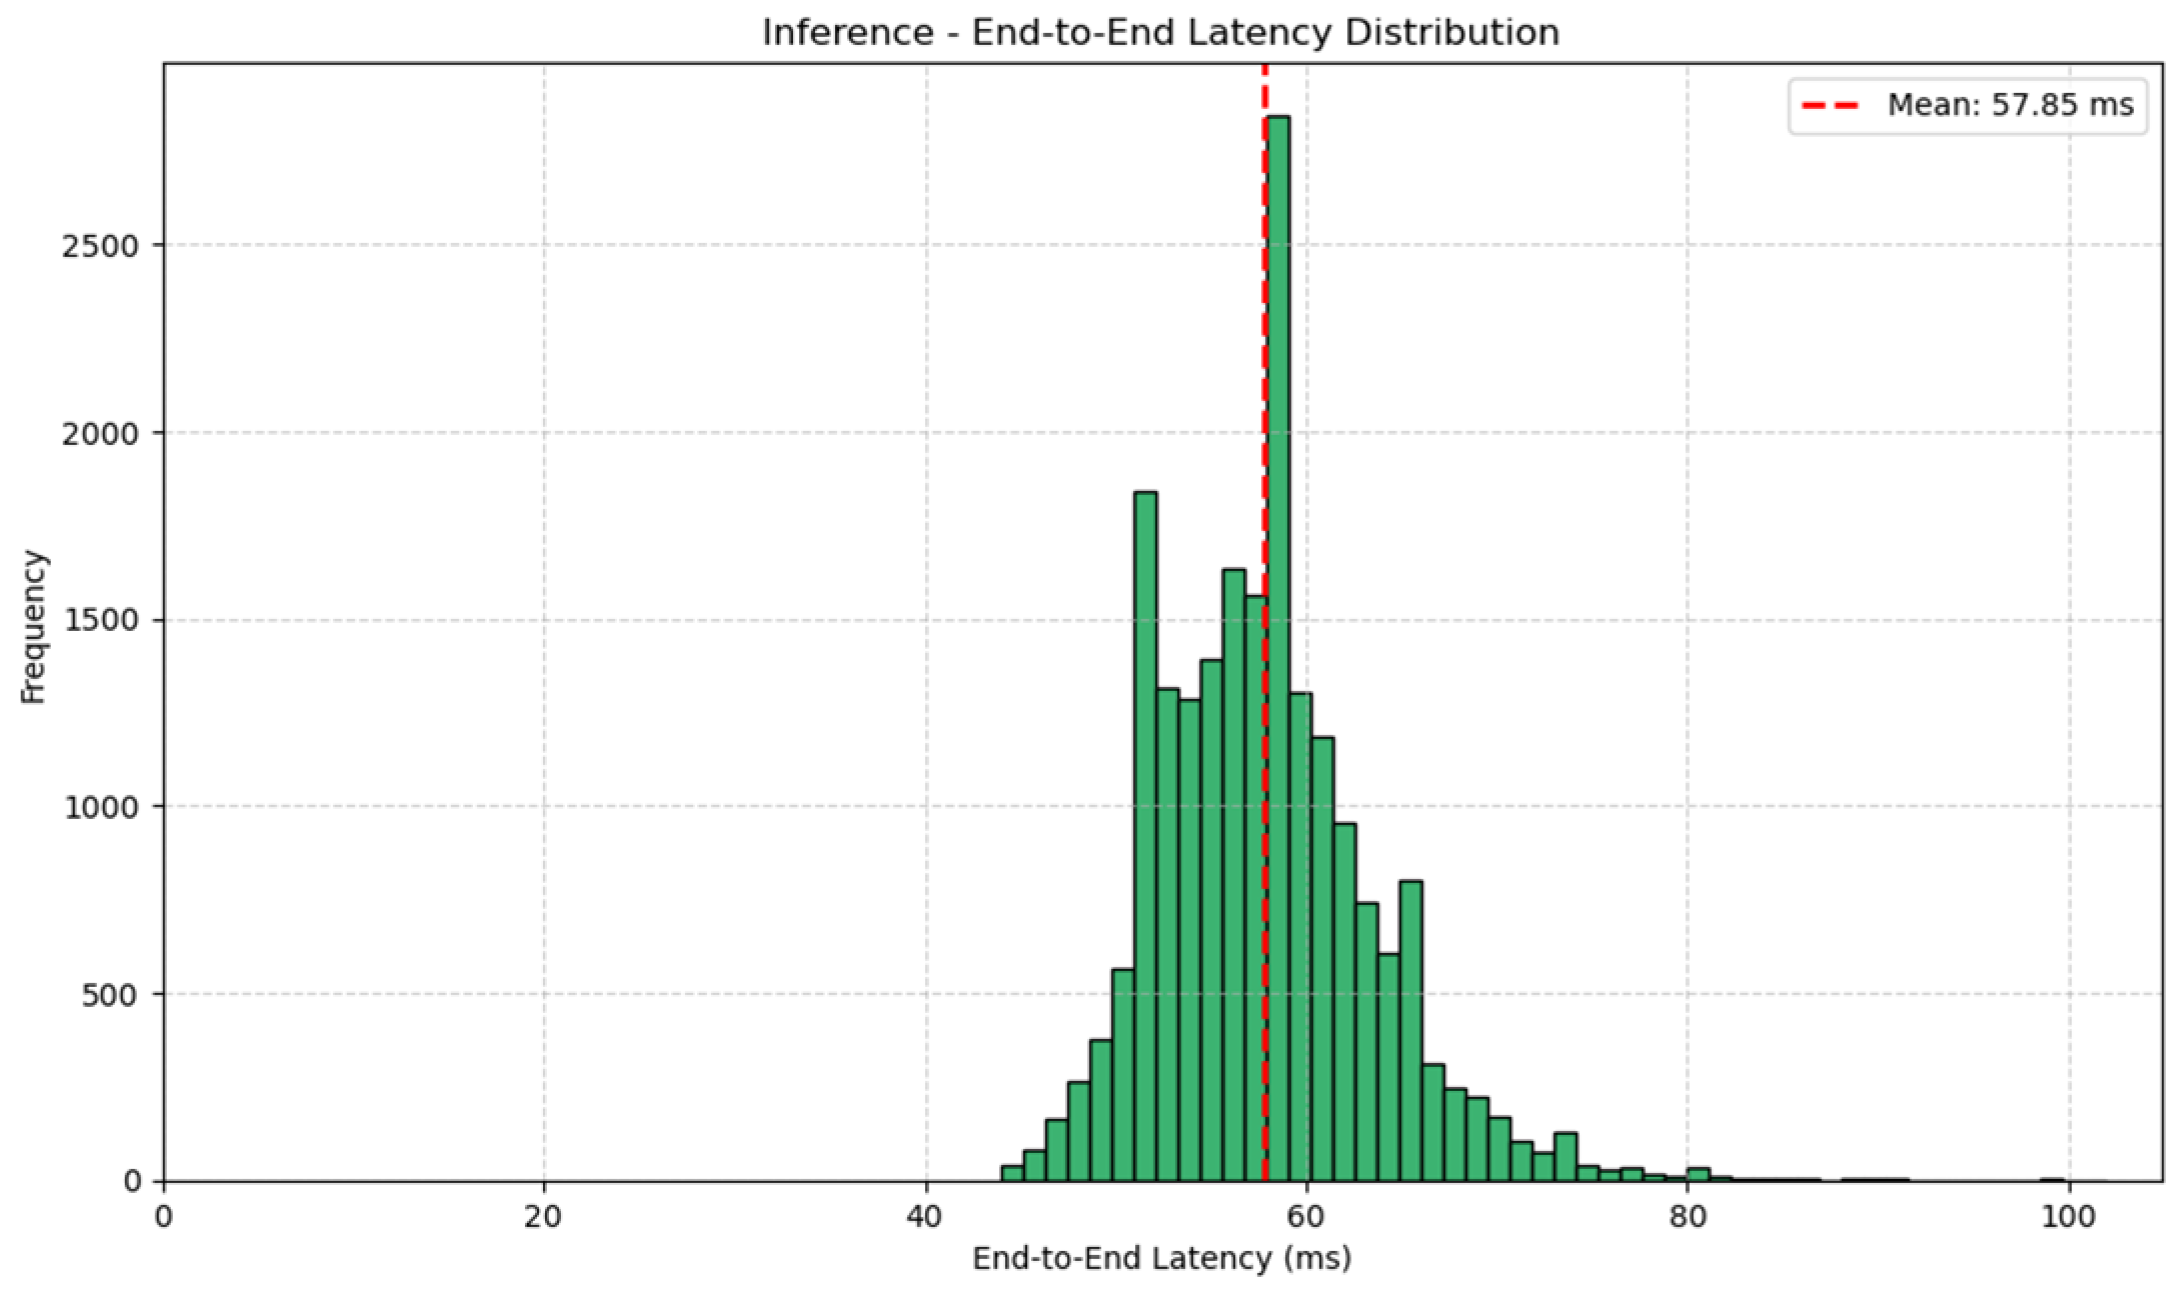
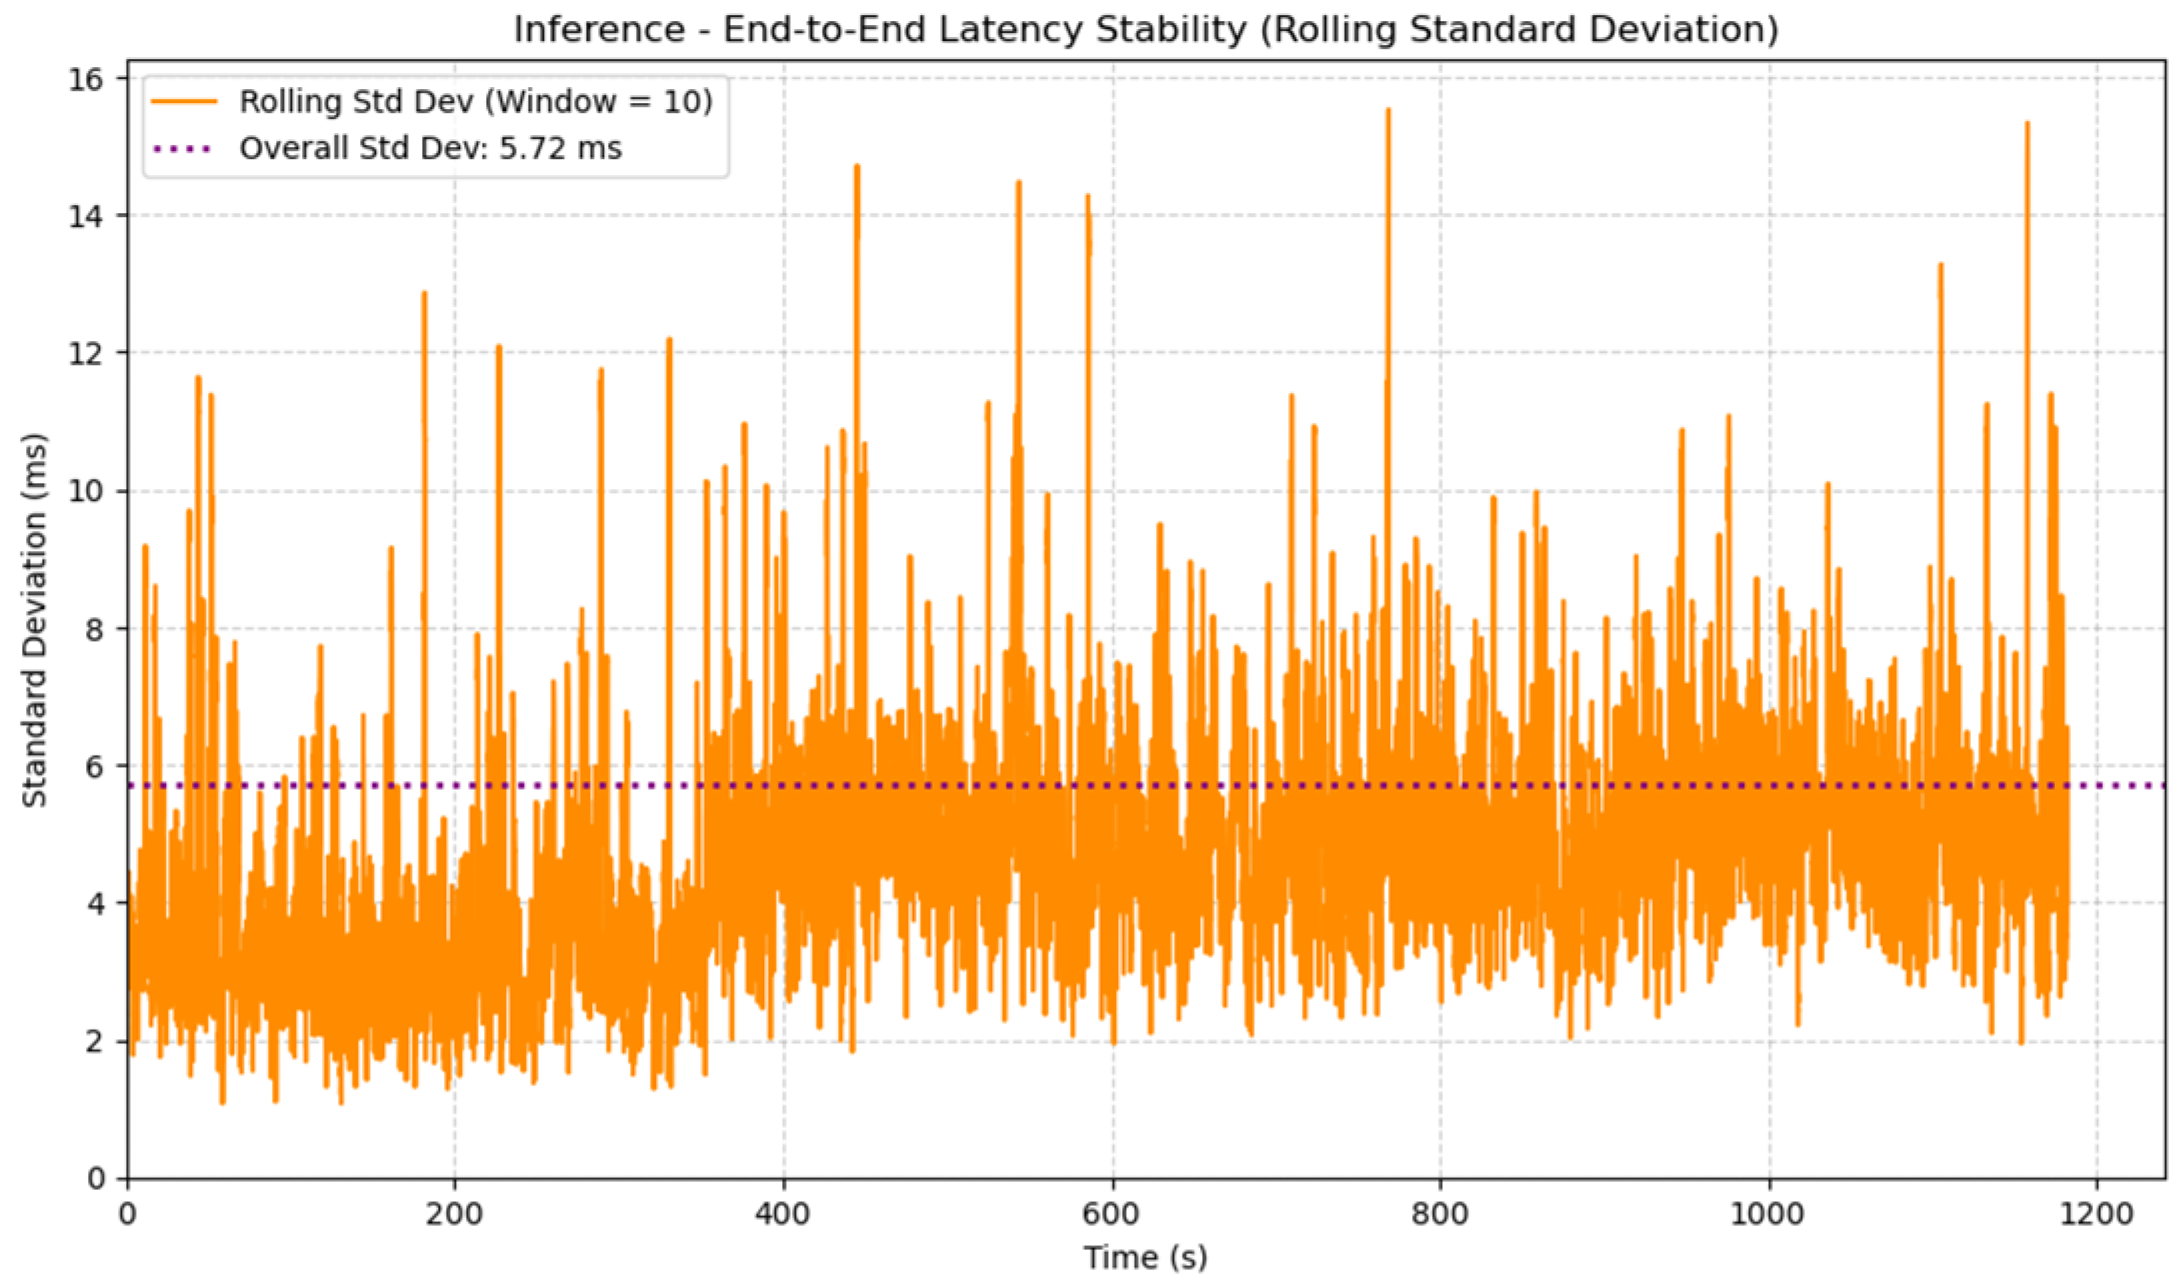
3.3. Inference End-to-End Latency
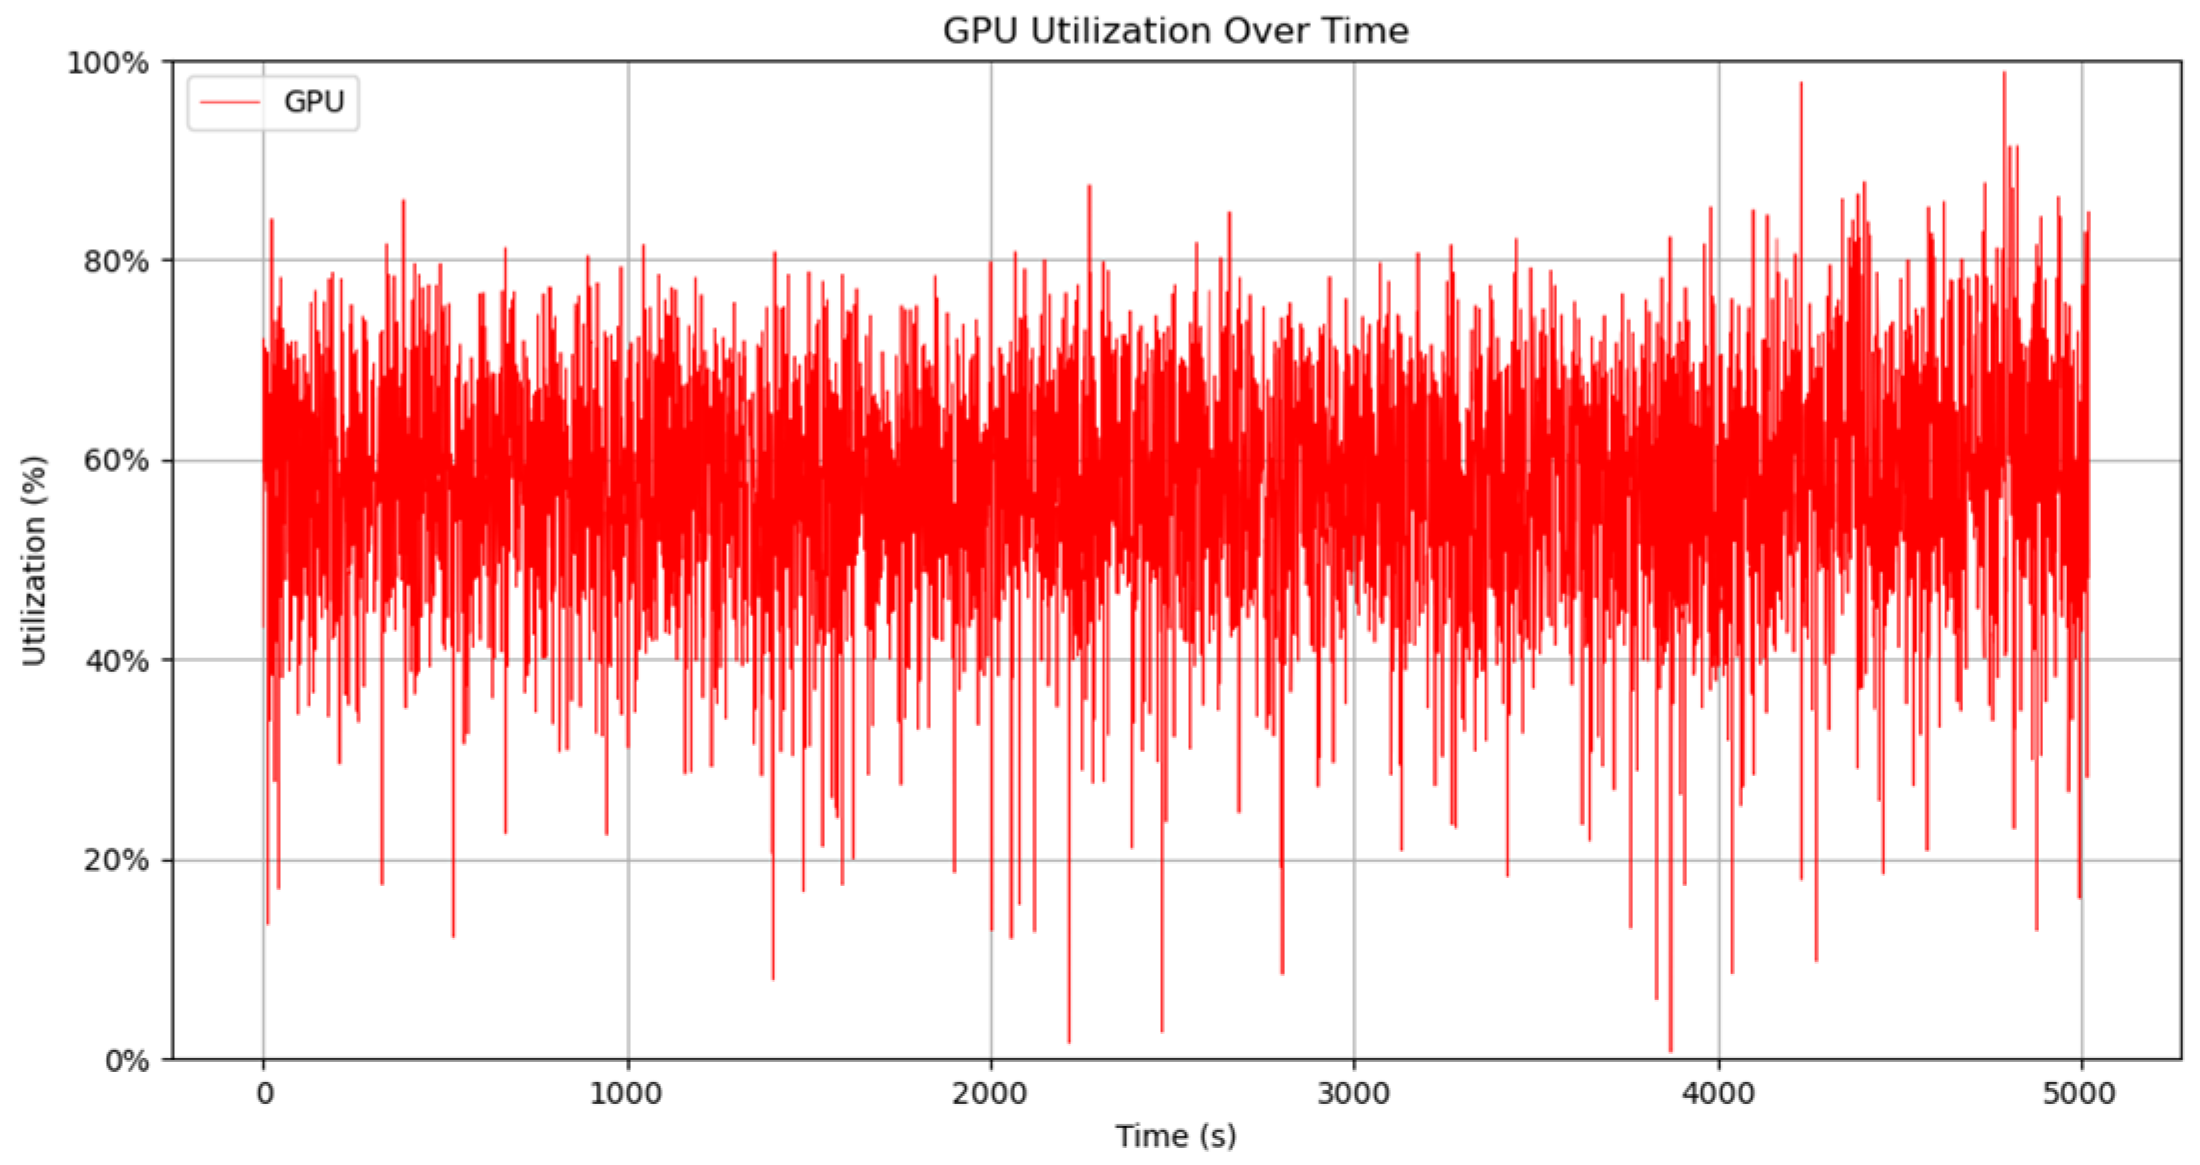
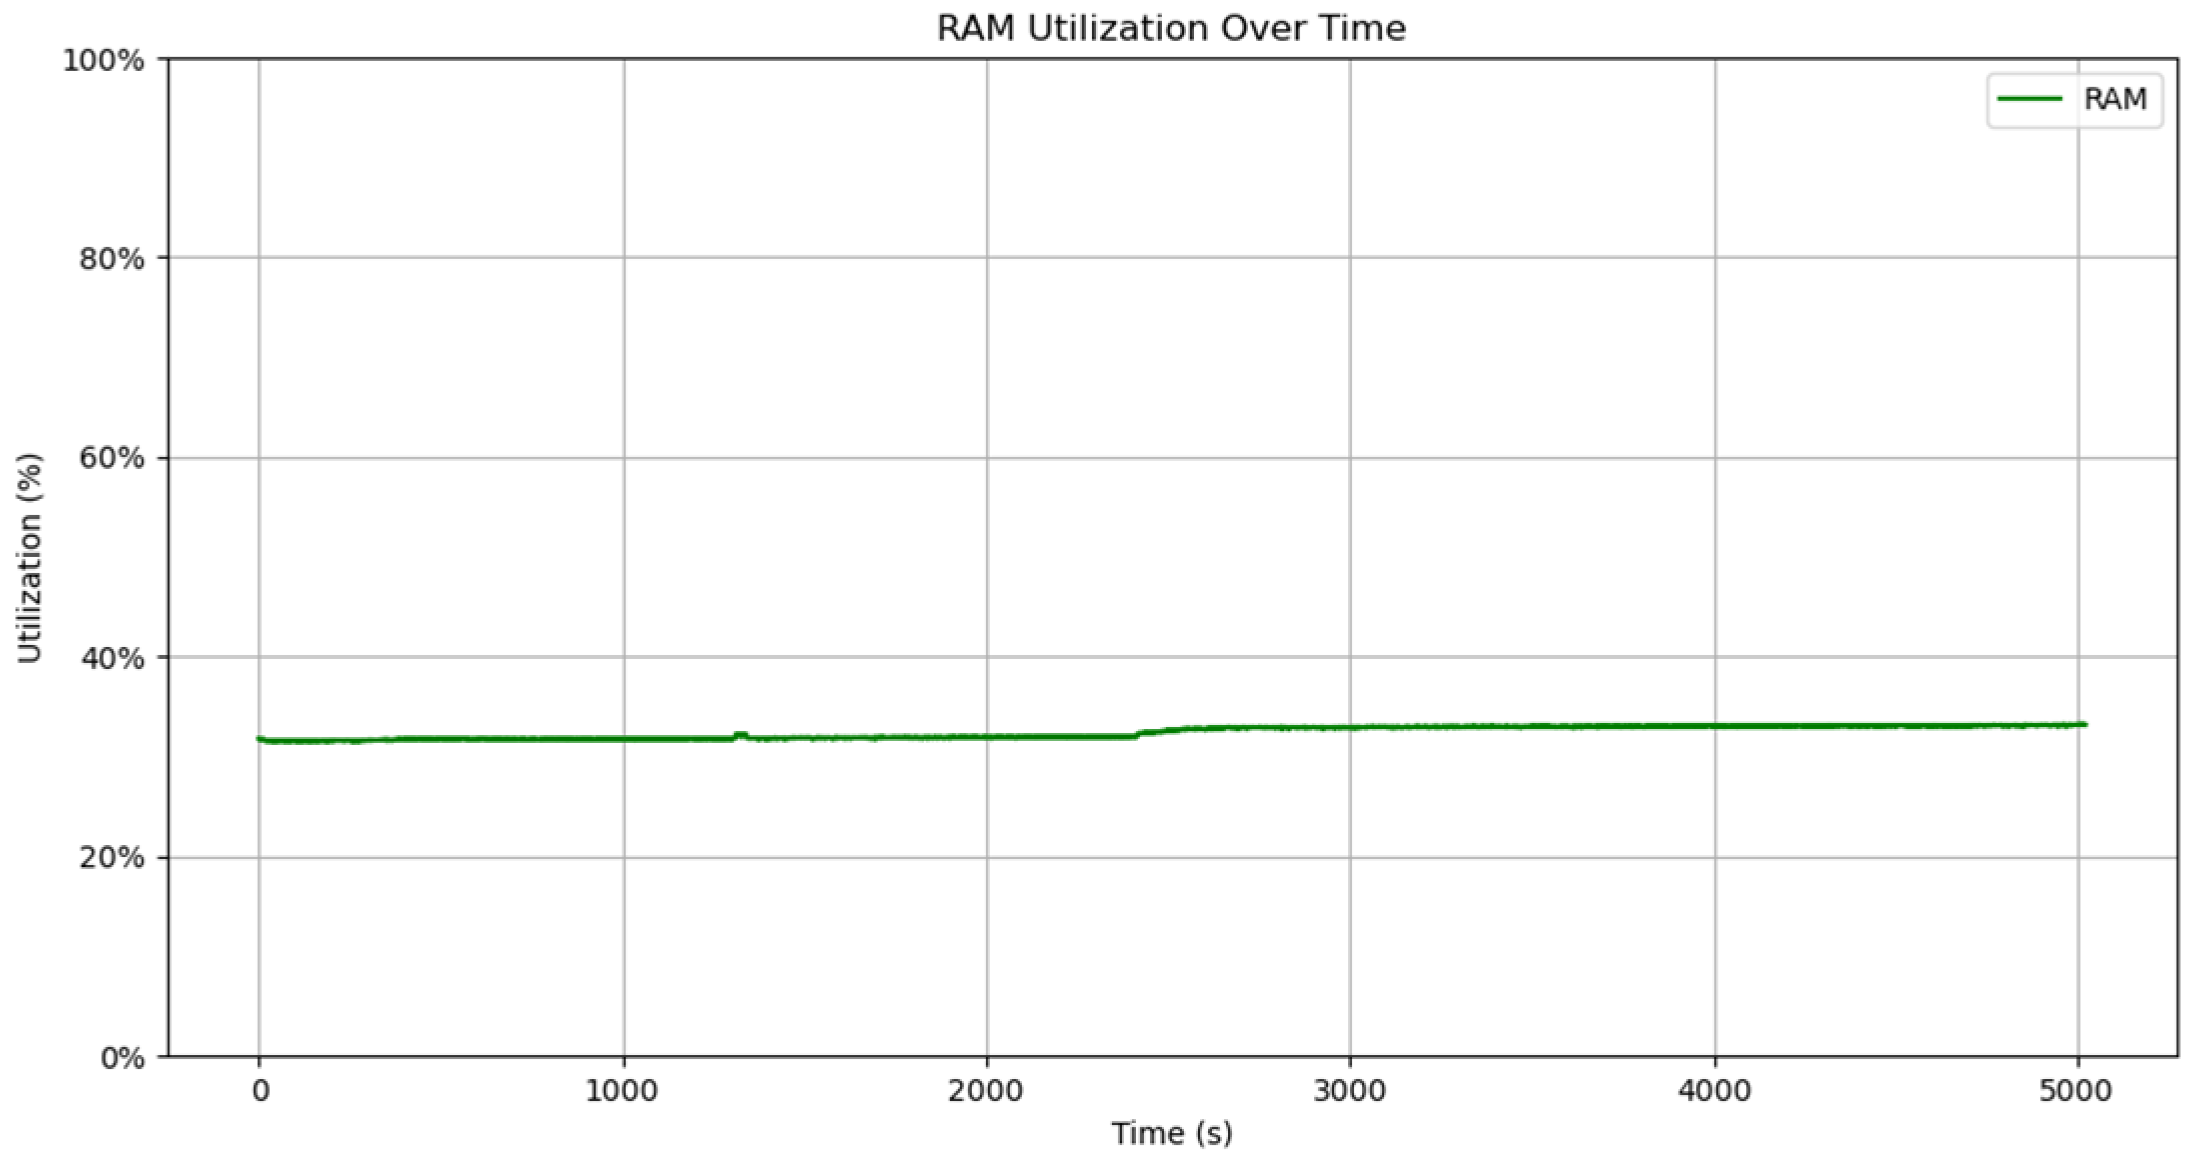
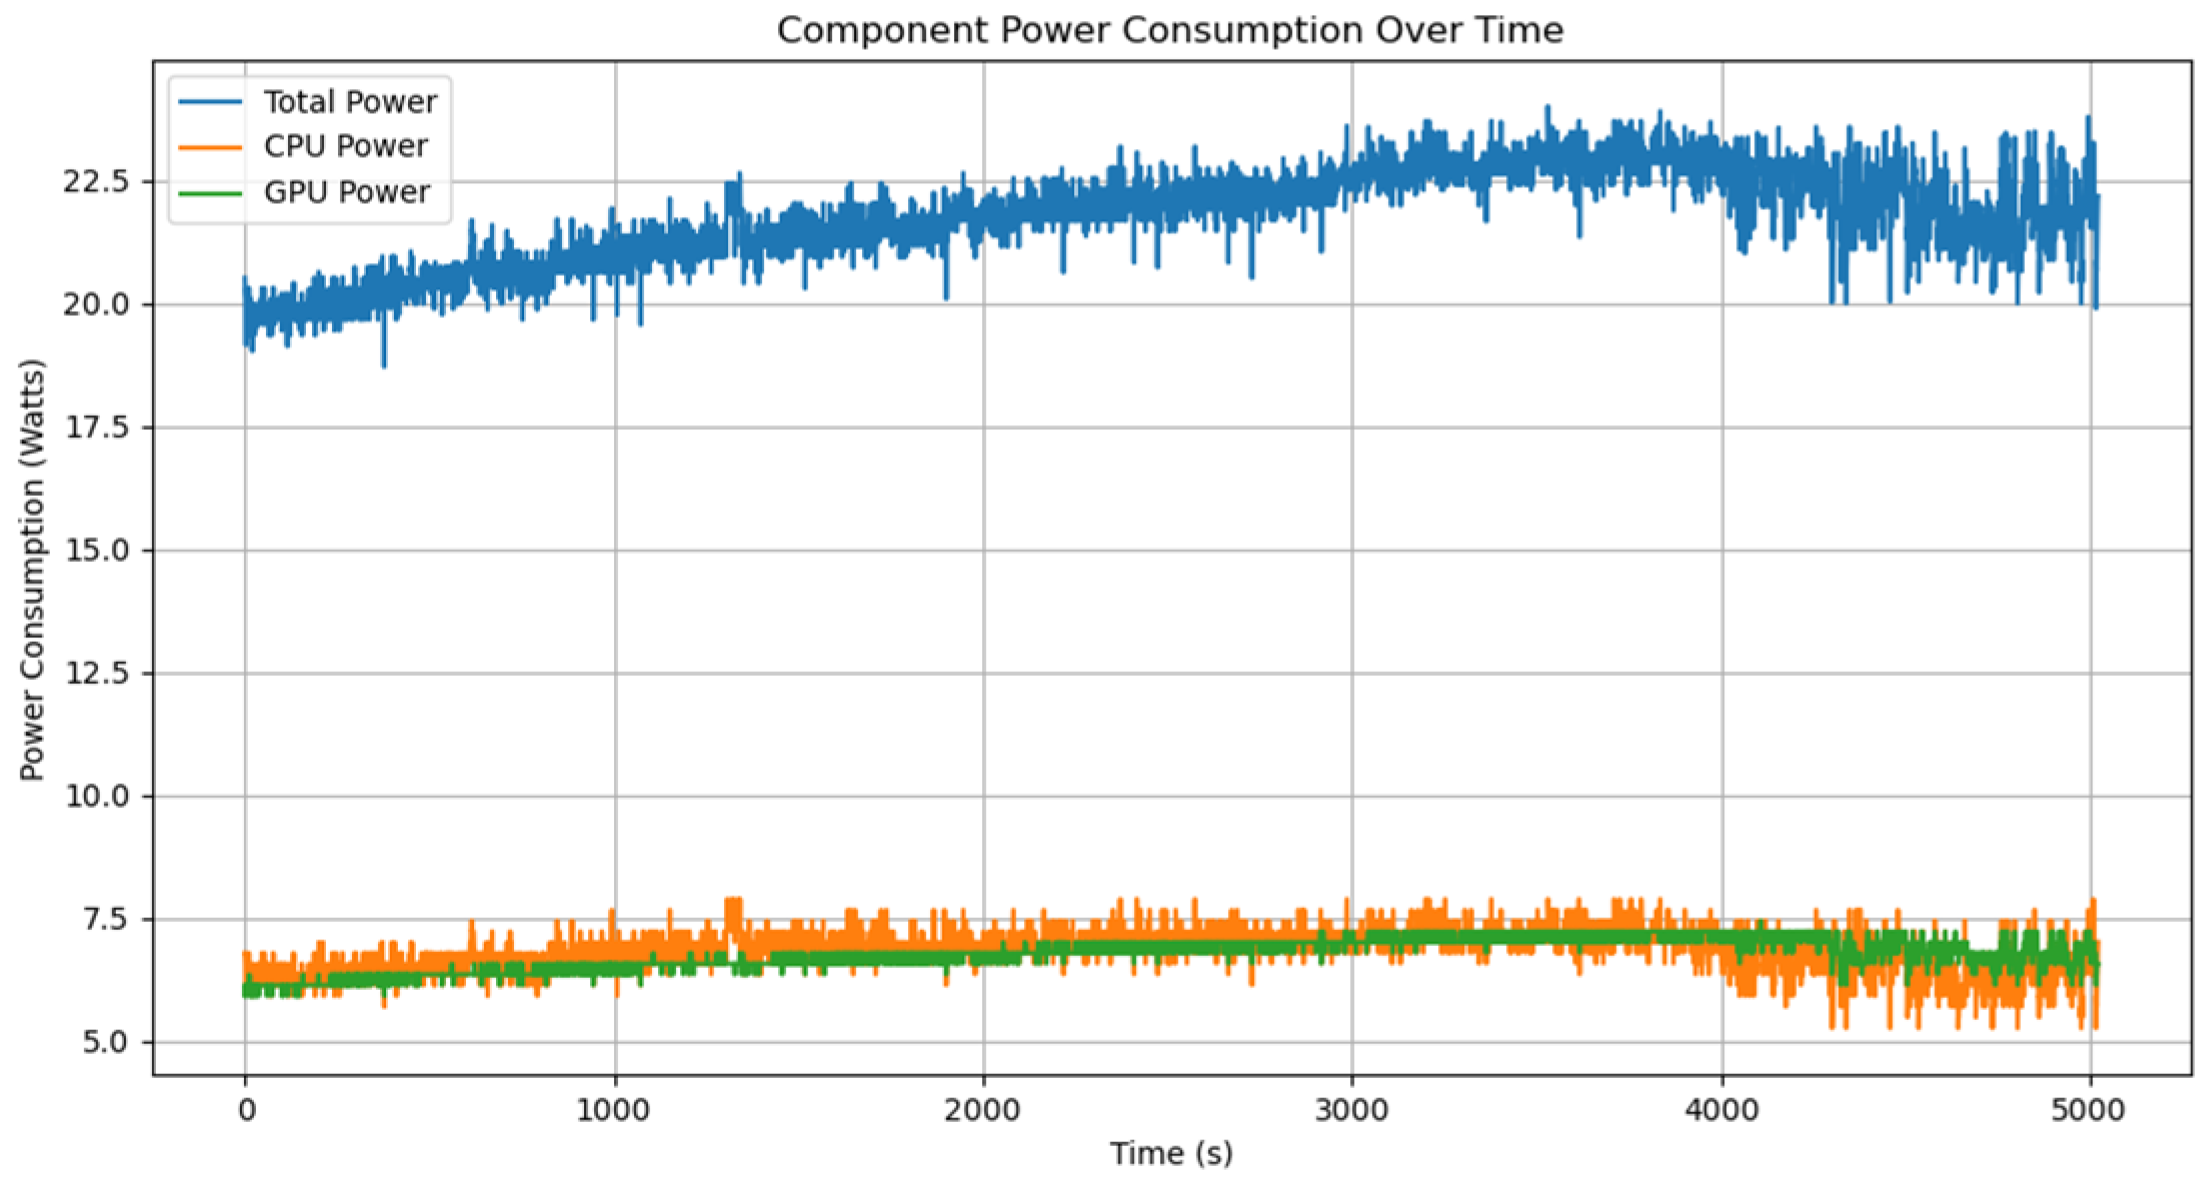
3.4. Hardware Utilization and Power Consumption
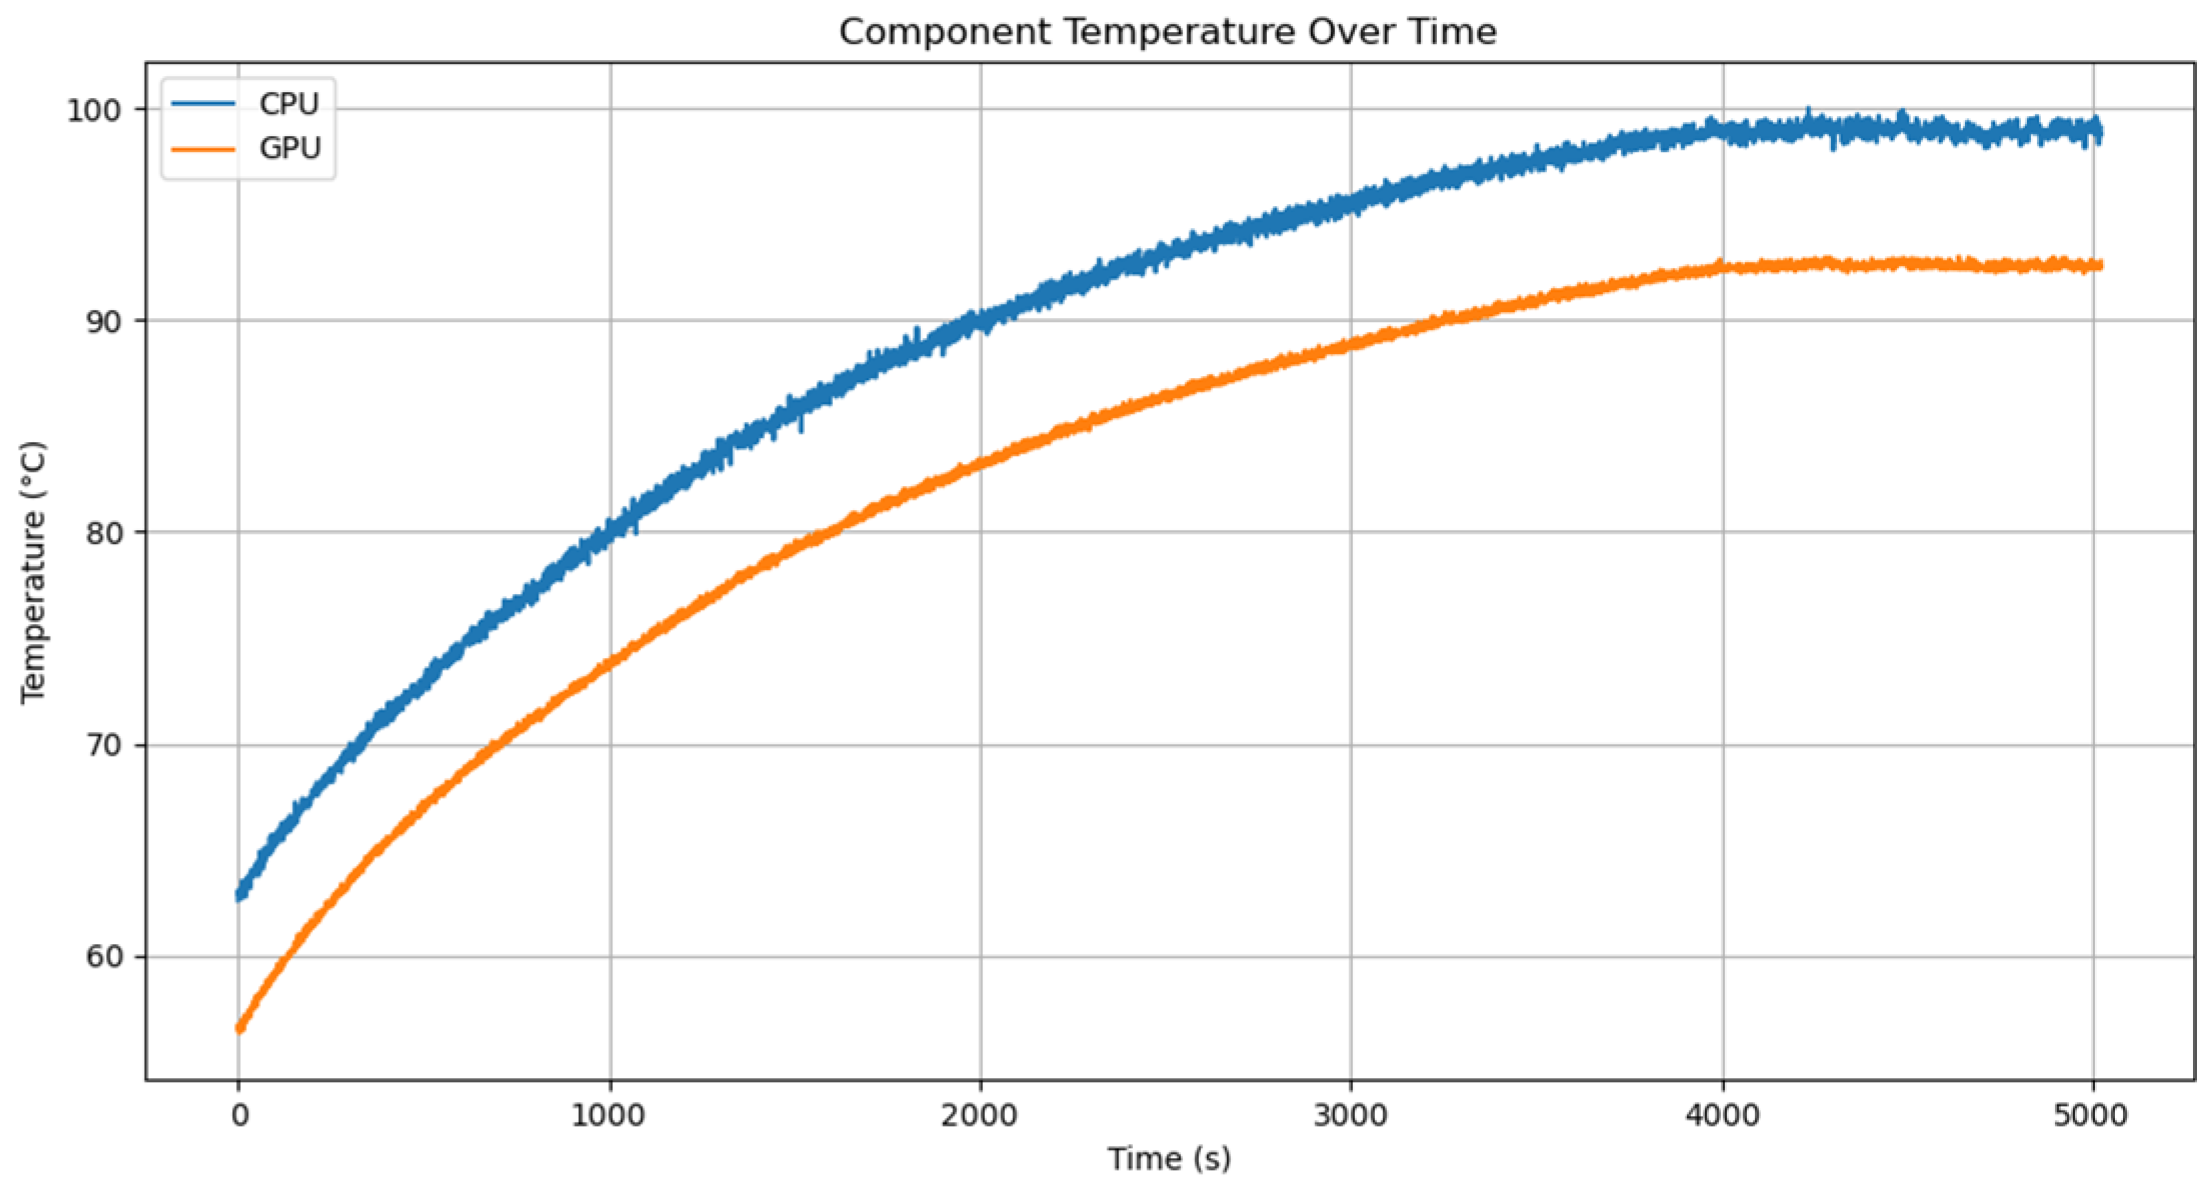
3.5. Thermal Performance
4. Discussion
Author Contributions
Funding
Data Availability Statement
Acknowledgments
Conflicts of Interest
Abbreviations
| ADAS | Advanced Driver Assistance System |
| EPAS | Electronic Power Assisted Steering |
| GMSL2 | Second-Generation Gigabit Multimedia Serial Link |
| CAN-FD | Controller Area Network Flexible Data-Rate |
| DBC | CAN Database |
| MPC | Model Predictive Control |
| BGR | Blue-Green-Red |
| RGBA | Red-Green-Blue-Alpha |
| PSCM | Power Steering Control Module |
| DVFS | Dynamic Voltage and Frequency Scaling |
References
- Nvidia DRIVE Quote Request. Available online: https://arrow.tfaforms.net/5113032 (accessed on 7 January 2026).
- DRIVE AGX Developer Kits. Available online: https://developer.nvidia.com/drive/agx#section-orin-hardware-accessories (accessed on 15 January 2026).
- Nvidia DRIVE OS Linux SDK API Reference. Available online: https://developer.nvidia.com/docs/drive/drive-os/6.0.10/public/drive-os-linux-sdk/api_reference/files.html (accessed on 8 January 2026).
- Nanz, S.; Furia, C.A. A Comparative Study of Programming Languages in Rosetta Code. In Proceedings of the 2015 IEEE/ACM 37th IEEE International Conference on Software Engineering, Florence, Italy, 16–24 May 2015; pp. 778–788. [Google Scholar] [CrossRef] [Scilit]
- Apollo. Available online: https://github.com/ApolloAuto/apollo?tab=readme-ov-file#architecture (accessed on 7 January 2026).
- Apollo Hardware Development Platform. Available online: https://developer.apollo.auto/platform/hardware.html (accessed on 15 January 2026).
- Openpilot—Open Source Advanced Driver Assistance System. Available online: https://comma.ai/openpilot (accessed on 15 January 2026).
- Openpilot process_config.py. Available online: https://github.com/commaai/openpilot/blob/master/system/manager/process_config.py (accessed on 7 January 2026).
- Openpilot service.py. Available online: https://github.com/commaai/openpilot/blob/master/cereal/services.py (accessed on 7 January 2026).
- Comma Four. Available online: https://comma.ai/shop/comma-four (accessed on 15 January 2026).
- How Openpilot Works in 2021. Available online: https://blog.comma.ai/openpilot-in-2021/ (accessed on 15 January 2026).
- Goff, M.; Hogan, G.; Hotz, G.; du Parc Locmaria, A.; Raczy, K.; Schäfer, H.; Shihadeh, A.; Zhang, W.; Yousfi, Y. Learning to Drive from a World Model. arXiv 2025, arXiv:2504.19077. [Google Scholar] [CrossRef] [Scilit]
- Openpilot. Available online: https://github.com/commaai/openpilot?tab=MIT-1-ov-file#readme (accessed on 19 August 2025).
- MIT License. Available online: https://choosealicense.com/licenses/mit/ (accessed on 19 August 2025).
- Multiprocessing—Process-Based Parallelism—Python 3.8.3rc1 Documentation. Available online: https://docs.python.org/3/library/multiprocessing.html (accessed on 7 December 2025).
- Vasu, P.K.A.; Gabriel, J.; Zhu, J.; Tuzel, O.; Ranjan, A. FastViT: A Fast Hybrid Vision Transformer using Structural Reparameterization. arXiv 2023, arXiv:2303.14189. [Google Scholar] [CrossRef] [Scilit]
- Ge, Q.; Sun, Q.; Li, S.E.; Zheng, S.; Wu, W.; Chen, X. Numerically Stable Dynamic Bicycle Model for Discrete-Time Control. In Proceedings of the 2021 IEEE Intelligent Vehicles Symposium Workshops, Nagoya, Japan, 11–12 July 2021; pp. 128–134. [Google Scholar] [CrossRef] [Scilit]
- Neural Networks in Openpilot. Available online: https://github.com/commaai/openpilot/tree/master/selfdrive/modeld/models (accessed on 26 January 2026).
- Parse_model_outputs.py. Available online: https://github.com/commaai/openpilot/blob/master/selfdrive/modeld/parse_model_outputs.py (accessed on 26 January 2026).
- Deepview Corp. AI Vehicle Computer (Devkit). Available online: https://www.deepviewai.com/_files/ugd/51ea66_afd601f136fd473eafbf55eca3c9fa07.pdf (accessed on 19 August 2025).
- Karumbunathan, L. NVIDIA Jetson AGX Orin Series a Giant Leap Forward for Robotics and Edge AI Applications Technical Brief. Available online: https://www.nvidia.com/content/dam/en-zz/Solutions/gtcf21/jetson-orin/nvidia-jetson-agx-orin-technical-brief.pdf (accessed on 19 August 2025).
- Boland, H.M.; Burgett, M.I.; Etienne, A.J.; Stwalley, R.M., III. An Overview of CAN-BUS Development, Utilization, and Future Potential in Serial Network Messaging for Off-Road Mobile Equipment. In Technology in Agriculture; IntechOpen: London, UK, 2021. [Google Scholar] [CrossRef] [Scilit]
- StereoLabs. ZED X One Camera and SDK Overview. Available online: https://www.stereolabs.com/products/zed-x-one (accessed on 19 August 2025).
- Wang, K. Gigabit Multimedia Serial Link (GMSL) Cameras as an Alternative to GigE Vision Cameras. ADI Analog Dialogue 2023, 57, 3–4. [Google Scholar]
- Openpilot Safety. Available online: https://github.com/commaai/openpilot/blob/master/docs/SAFETY.md (accessed on 19 January 2026).
- Saez-Perez, J.; Diez-Tomillo, J.; Tena-Gago, D.; Alcaraz-Calero, J.M.; Wang, Q. Design, Implementation and Validation of a Level 2 Automated Driving Vehicle Reference Architecture. Expert Syst. 2025, 42, e70050. [Google Scholar] [CrossRef] [Scilit]
- Deng, Z.; Zhang, Z.; Li, D.; Guo, Y.; Ye, Y.; Ren, Y.; Jia, N.; Hu, X. Interference-Free Operating System: A 6 Years’ Experience in Mitigating Cross-Core Interference in Linux. In Proceedings of the 2024 IEEE Real-Time Systems Symposium (RTSS), York, UK, 10–13 December 2024; pp. 308–321. [Google Scholar] [CrossRef] [Scilit]
- Limpert, E.; Stahel, W.A.; Abbt, M. Log-Normal Distributions across the Sciences: Keys and Clues. BioScience 2001, 51, 341–352. [Google Scholar] [CrossRef] [Scilit]
- Gao, Y.; He, Y.; Li, X.; Zhao, B.; Lin, H.; Liang, Y.; Zhong, J.; Zhang, H.; Wang, J.; Zeng, Y.; et al. An Empirical Study on Low GPU Utilization of Deep Learning Jobs. In Proceedings of the IEEE/ACM 46th International Conference on Software Engineering (ICSE ’24), Lisbon, Portugal, 14–20 April 2024; pp. 1–13. [Google Scholar] [CrossRef] [Scilit]
- Benoit-Cattin, T.; Velasco-Montero, D.; Fernández-Berni, J. Impact of Thermal Throttling on Long-Term Visual Inference in a CPU-Based Edge Device. Electronics 2020, 9, 2106. [Google Scholar] [CrossRef] [Scilit]
- Praveen, S.M.; Rammohan, A. Active and Passive Cooling Techniques of Graphical Processing Units in Automotive Applications—A Review. Eng. Res. Express 2024, 6, 022506. [Google Scholar] [CrossRef] [Scilit]
- Wang, S. Evaluating Cross-Building Transferability of Attention-Based Automated Fault Detection and Diagnosis for Air Handling Units: Auditorium and Hospital Case Study. Build. Environ. 2026, 287, 113889. [Google Scholar] [CrossRef] [Scilit]






Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Giuliani, M.; Pappas, G. Evaluating the X2000: A Novel Integrated Platform for Rapid ADAS Development. Electronics 2026, 15, 679. https://doi.org/10.3390/electronics15030679
Giuliani M, Pappas G. Evaluating the X2000: A Novel Integrated Platform for Rapid ADAS Development. Electronics. 2026; 15(3):679. https://doi.org/10.3390/electronics15030679
Chicago/Turabian StyleGiuliani, Michael, and George Pappas. 2026. "Evaluating the X2000: A Novel Integrated Platform for Rapid ADAS Development" Electronics 15, no. 3: 679. https://doi.org/10.3390/electronics15030679
APA StyleGiuliani, M., & Pappas, G. (2026). Evaluating the X2000: A Novel Integrated Platform for Rapid ADAS Development. Electronics, 15(3), 679. https://doi.org/10.3390/electronics15030679