


Abstract
The district heating system (DHS) can provide flexibility to the electrical power system (EPS) in the coordinated dispatch of an integrated power and heat system (IPHS). To exploit the energy storage capacity of the DHS and support the flexible IPHS operation, it is essential to characterize the flexible operation region (FOR) of the DHS. This paper proposes an FOR characterization method for the DHS, based on a Farkas-cut outer approximation algorithm (FCOAA). The FOR characterization is formulated as a polyhedral projection problem. Within the FCOAA-based framework, the feasible cut generation model is constructed as a bilinear programming problem, which is relaxed by using the normalized multiparametric disaggregation technique (NMDT) and converted into a mixed-integer linear programming (MILP) problem. Numerical simulations on a 6-bus/6-node IPHS are carried out to validate the proposed method, and key factors influencing the flexibility of the DHS are analyzed.
1. Introduction
The large-scale integration of renewable energy sources substantially increases the scheduling burden on the electrical power system (EPS), making the harnessing of flexible resources a key prerequisite for secure operation [1,2]. As the coupling between the district heating system (DHS) and the EPS deepens, integrated power and heat systems (IPHS) are increasingly regarded as an effective means to enhance system flexibility [3,4], since the inherent thermal storage capacity of the DHS, embodied in the heating network [5], dedicated thermal energy storage (TES) [6], and the thermal inertia of buildings [7], can be exploited to support flexible EPS operation [8]. Consequently, the characterization of DHS flexibility has attracted considerable research interest.
In recent years, numerous studies have focused on quantifying the flexibility of the DHS. In [9], a feasible region method is proposed to determine the adjustable operating range of the DHS, in which building thermal inertia is abstracted as virtual energy storage and is incorporated into IPHS dispatch. In [10], the heating network is equivalently modeled as TES in IPHS scheduling, the flexibility indicators for ramp rate, power, and energy are defined, and the impact of different DHS control strategies on system flexibility is evaluated. In [11], a DHS flexibility quantification method is developed, based on the decomposition of pipeline subsystems and detailed modeling of pipeline thermal dynamics, and the flexibility is compared under different pipeline lengths, supply temperatures, heat loads, and other operating conditions. In [12], a quantitative method for the spatio-temporal thermal dynamic flexibility of the DHS is established, flexibility indicators for capacity, amplitude, and duration are defined, and the potential and influencing factors of the DHS in providing scheduling buffers for the power grid are analyzed. In [13], a regulating region method is proposed to quantify the available reserve capacity of the DHS supplied by the combined heat and power (CHP), and it is shown that neglecting the coupling constraints of the DHS results in inaccurate estimation of the available reserve margin. However, the existing studies often quantify DHS flexibility in terms of single-time power/reserve intervals or aggregate flexibility indicators, lacking a high-dimensional feasible region characterization of electro-thermal coupling control variables over the entire scheduling horizon. As a result, it remains challenging to provide a trajectory-level representation of the flexible operation region (FOR) that can be directly embedded into coordinated IPHS scheduling.
FOR has been widely used to quantify the flexibility of resources in EPS, including distribution networks [14], microgrids [15], and regional integrated energy systems [16]. In these studies, an outer approximation algorithm is adopted to characterize the FOR, which is formulated as a polyhedral projection problem. Existing FOR characterization frameworks typically employ the big-M method to convert the nonconvex problem into a mixed-integer linear programming (MILP) problem. However, this approach performs poorly on high-dimensional and strongly coupled polyhedral projection problems. It usually chooses big-M constants conservatively, which weakens the relaxation and causes severe numerical difficulties. Thus, the branch-and-bound tree in the projection space can become extremely large and the solution time may be prohibitive. Therefore, alternative approaches are needed to handle the nonconvexities arising in polyhedral projection.
According to [16], characterization of the FOR inevitably leads to bilinear programming problems. Global optimizers such as Gurobi [17] and BARON [18] can solve these problems by using spatial branch-and-bound, based on convex relaxation models like the McCormick envelope. Nevertheless, when dealing with large-scale problems, spatial branch-and-bound also suffers from an exponential increase in complexity and difficulty in convergence due to a rapidly increasing solution time. To tighten the convex relaxations, piecewise McCormick envelopes [19] and multiparametric disaggregation [20] have been proposed. In [21], the relaxation accuracy and computational efficiency of these two methods are compared, and results show that, for the same number of partitions, multiparametric disaggregation yields smaller MILP formulations with fewer binary variables. This is because the number of binary variables in multiparametric disaggregation grows logarithmically with the number of partitions, whereas it increases linearly in piecewise McCormick envelopes. In [22], the normalized multiparametric disaggregation technique (NMDT) is proposed to improve multiparametric disaggregation, and numerical experiments show that it is more computationally efficient than piecewise McCormick envelopes.
Considering the aforementioned aspects, this paper proposes a Farkas-cut outer approximation algorithm (FCOAA) to characterize the FOR of the DHS, where the characterization problem is formulated as a polyhedral projection problem. The NMDT model is introduced to transform bilinear programming problems arising in the feasible cut generation process into MILP problems. The main contributions of this paper are summarized as follows:
- (1)
- The FOR of the DHS is defined based on a detailed DHS model. An outer approximation algorithm is developed to solve the associated polyhedral projection problem by iteratively identifying infeasible points and generating feasible cuts, according to Farkas’ lemma. The resulting FOR is used to construct a coordinated scheduling framework for the IPHS.
- (2)
- The NMDT relaxation is employed to reformulate the bilinear programming problems as MILP problems. A global optimization framework is established, within which the NMDT relaxation is progressively tightened until globally optimal feasible cuts are obtained. This NMDT-based global optimization procedure is then embedded into the outer approximation algorithm.
2. Formulation of the Flexible Operation Region
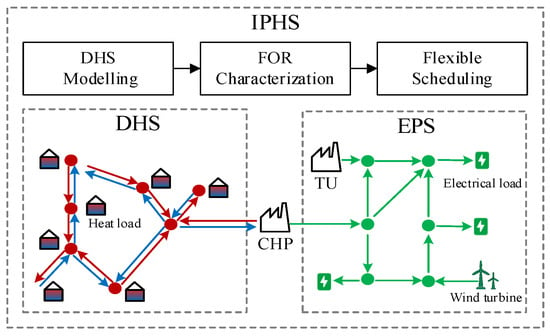
The IPHS consists of an EPS and a DHS. A typical configuration of such a system is shown in Figure 1. The CHP is usually regarded as the coupling unit between the EPS and the DHS, serving simultaneously as both a heat source and a power source. On the DHS side, the thermal energy produced by the CHP unit is transported through the heating network to satisfy the terminal heat demand. On the EPS side, the CHP unit, conventional thermal power units, and clean energy generation units together constitute the electricity production subsystem. The electricity–heat coordinated scheduling framework based on the FOR of the DHS is also illustrated in Figure 1.
Figure 1.
Schematic diagram of IPHS- and FOR-based coordinated dispatch scheme.
2.1. District Heating System Model
The DHS consists of heat sources, heating networks, and heat loads. To capture the impact of the DHS operating constraints on the FOR, a detailed DHS model is developed. In this paper, the thermal power injected into the heating networks is regulated by adjusting the supply water temperature (i.e., quality regulation): a control strategy widely adopted in DHSs across northern China.
- (1)
- CHP model
The CHP is considered to be the coupling unit between the DHS and the EPS. There is a coupling relationship between the electric output and thermal output of a CHP unit, which is denoted as follows:
where is the heat output of CHP unit g at period t; is the power output of CHP unit g at period t; and is the heat-to-power ratio of CHP unit g. The of back-pressure CHP is fixed, while the of extraction CHP is adjustable. is the set of all CHP units. The CHP should satisfy the capacity constraints:
where and are the maximum and minimum power output of unit g.
The flexibility of CHP units is constrained by their ramping limits. The characterization of the FOR must take these ramping constraints into account, as shown in (3).
where and are the upward and downward ramping limits of unit g.
- (2)
- Heating network model
The thermal energy exchange between heat source/load nodes and the heating network is described by the energy balance constraints. Assuming that the DHS has only one heat source node, the energy balance constraints are denoted as follows:
where is the mass flow rate of pipeline l at period t; and are the inlet and outlet temperature of supply pipeline l at period t; and are the inlet and outlet temperature of return pipeline l at period t; is the specific heat capacity of the thermal energy carrier; is the thermal power of heat load n at period t; is the set of heat load nodes; and and are the sets of outflow and inflow pipelines associated with node n, respectively.
Under quality regulation, the hydraulic state remains stable, allowing the mass flow rate to be treated as parameter. The thermal dynamics model is established as implicit finite difference equations to describe the temperature variation along the pipeline, as shown in (6) and (7). In addition, it is worth noting that the proposed model does not necessarily require a constant mass flow rate; a pre-specified flow-adjustment profile over the entire scheduling horizon is fully acceptable.
where is the length of pipeline l; is the inner diameter of pipeline l; is the heat loss coefficient of pipeline l; is the density of the thermal energy carrier; is the time step of combined heat and power dispatch; is the outdoor temperature at time t; is the average temperature of supply pipeline l at period t; is the average temperature of return pipeline l at period t; and is the set of pipelines.
Assuming that the water leaving the same node has a uniform temperature, the node’s mixing constraints, based on energy conservation, can be expressed as follows:
where is the set of mixing nodes, each of which has at least one outflow pipeline and one inflow pipeline.
2.2. IPHS Model
This paper considers the EPS constraints composed of power generation constraints and system-level constraints.
- (1)
- Power generation constraints
For the thermal power unit, the power capacity constraints should be satisfied, as shown in (10). The power output of adjacent time periods should follow the ramping constraints (11).
where is the power output of thermal power unit g at period t; and are the maximum and minimum power output of thermal power unit g; and are the upward and downward ramping limits of thermal power unit g; and is the set of all thermal power units.
For wind power generation, the output is constrained by the maximum available wind power:
where is the power output of wind farm g at period t and is the maximum available wind power output of wind farm g at period t. is the set of all wind farms.
- (2)
- Power system constraints
The power system constraints include three parts: power balance constraints, line capacity constraints, and spinning reserve constraints. To ensure the safety and reliability of the power supply, the system’s electric power and load need to be balanced in real time, and the power balance constraint is formulated as follows:
where is the power output of power generation unit g at period t; is the power of load k at period t; is the set of all power generation units, namely, ; and is the set of all electrical power loads.
The power flow of each line cannot exceed its capacity, and the line capacity constraint based on the DC power flow model is expressed as follows:
where is the capacity of power line l; and are the parameters in the power transfer distribution factor matrix, based on the DC power flow model; and the calculation method of the matrix can refer to reference [23].
Thermal power units provide the spinning reserve capacity required by the EPS, and the reserve capacity of the unit is represented in (15). The total reserve capacity provided by the units needs to be greater than the reserve capacity required by the EPS, as denoted in (16).
where and are the available upward/downward reserve capacity of unit g at period t and and are the upward/downward reserve capacity demands at period t.
- (3)
- Combined heat and power dispatch model
By integrating the DHS model into the EPS dispatch model, a combined heat and power dispatch framework can be formulated as follows:
where is the penalty factor for wind power curtailment and and are the power generation cost functions of the thermal power units and the CHP units.
2.3. Definition of FOR
The flexibility of the DHS can be characterized by the time-series power output of the CHP unit. The corresponding coupling variables can then be expressed as follows:
where is the vector of coupling variables of the DHS and is the number of time periods of the combined heat and power dispatch.
The flexibility of the DHS is constrained by its operation constraints, namely (1)–(9). The DHS model is transformed into the following compact form:
where is the state variables of the DHS; and are the corresponding coefficient matrices of and ; and is the constant vector of the DHS constraints.
Based on the compact form of the DHS model, the FOR is defined as the set of feasible operating points, , denoted as follows:
By incorporating the FOR model into the IPHS framework, the combined heat and power dispatch problem can be reformulated as follows:
However, replacing the DHS model with the FOR defined by the compact model does not actually simplify the scheduling formulation. Moreover, model (21) still requires the internal operational state, , from the DHS, which may increase the communication burden and raise privacy concerns for the DHS operator. Thus, the FOR characterization is reformulated as a polyhedral projection problem. By projecting the polyhedron in the space onto the space, the FOR can be converted to the following polyhedral:
By calculating matrix and vector , the FOR can be characterized by a set of constraints that only involve the coupling variables, .
3. Characterization Method of the Flexible Operation Region
3.1. FCOAA-Based Polyhedral Projection
According to the definition in (22), the FOR is characterized as a polyhedral projection. This paper proposes a FCOAA-based polyhedral projection method. The basic idea of the outer approximation algorithm is to start from a sufficiently large space and gradually cut off infeasible areas.
First, model (19) is converted into the linear system shown in (23). Model (23) is infeasible if, and only if, .
According to Farkas’ lemma, (23) is infeasible if, and only if, condition (24) holds the following:
Second, the FCOAA-based polyhedral projection method is formulated as problem (25). The first constraint defines a sufficiently large initial space , which ensures . This model is used to identify the infeasible region in . If the optimal value , then there exists satisfying (24), which implies that lies outside . If , then holds for , which indicates that , and thus .
Initialization of : In this paper, an axis-aligned bounding box of the space is constructed as the initial set, . This box is obtained by solving a sequence of linear programming (LP) problems, formulated as min/max s.t. , . This procedure yields 2T bounding hyperplanes—an upper cut and a lower cut for each time step. Each hyperplane represents the attainable maximum or minimum electrical output of the CHP unit at time t, and each extreme value is feasible under at least one full-horizon dispatch schedule.
Finally, the inequality is expanded to generate cutting planes. For each vector satisfying , a hyperplane that excludes the infeasible can be constructed, namely . By substituting the solution of problem (25) into this inequality, a cutting plane is obtained that removes while preserving all points in .
To conclude, the FCOAA-based polyhedral projection algorithm proceeds as follows:
Step 1 (initialization): Initialize a sufficiently large space. Define and ensure that .
Step 2 (detection of infeasible points via Farkas’ lemma): Solve model (25) and record the optimal value, , and the corresponding solution, . If , proceed to step 3; otherwise, the algorithm terminates and outputs .
Step 3 (generation of cutting plane): Generate a cutting plane by appending a new hyperplane to the last row of , and update the space accordingly.
3.2. NMDT Relaxation
To efficiently solve problem (25), the bilinear constraints must be relaxed. In this paper, NMDT is employed to relax the bilinear terms. The bilinear terms in can be expressed in the following general form:
where BL is the set of all bilinear terms in the model and is an auxiliary variable that represents the product of and . To define the set of variables that need to be discretized, is normalized:
where and are the lower limit and upper limit of , respectively. The auxiliary variable represents as a linear combination of and . is expanded in binary form to obtain the following:
where is the exponent of discrete variables; denotes the discretization accuracy and is partitioned into segments of size ; is a binary variable that takes the value 0 or 1 at the th position; and is a slack variable that compensates for the discrepancy between the discrete variables and the original variables.
Multiplying the variable by Equation (28) and introducing to replace yields the expression for the bilinear variable :
Unlike the discrete variable , the variable remains continuous, and auxiliary variables are introduced to decompose . Multiplying the variable by Equation (29) and using auxiliary variables and to replace and , the following expression is obtained:
where is the product of two continuous variables, which are relaxed using the McCormick envelope [24], as given in Equations (33)–(35), and is the product of a continuous variable and a binary variable, which are handled by exact linearization techniques [25], as given in Equations (36) and (37).
In summary, the NMDT-based bilinear variable relaxation model is given in (38). Define as the product of the i-th element of and the j-th element of ; the NMDT relaxation of bilinear terms in (25) is derived in (39). Then, the bilinear programming problem in (25) is relaxed to the MILP formulation shown in (40):
Model (40) can be efficiently solved by off-the-shelf MILP solvers. However, it only provides an upper bound (UB) for the original problem (25). The tightness of the relaxation in (40) depends on the number of segments used to discretize the variables. According to (29), a smaller (i.e., a finer segmentation) generates more binary variables and yields a tighter formulation and thus a tighter upper bound. Therefore, we tighten the MILP model by decreasing to progressively approximate the optimal solution of (25).
3.3. Flowchart of FOR Characterization Method
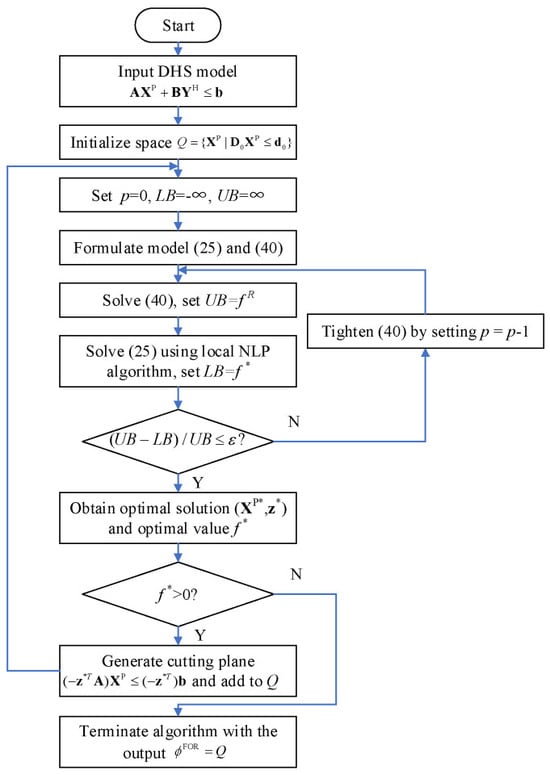
The overall framework of the FOR characterization is illustrated in Figure 2.
Figure 2.
Flowchart of the FOR characterization method.
The outer loop of the flowchart implements the polyhedral projection algorithm described in Section 3.1. In the inner iteration, model (40) is solved to obtain UB, while (25) is solved using a local NLP solver to obtain the lower bound (LB). The inner loop is initialized with , which yields the most tractable relaxation without binary variables. If the convergence criterion is not satisfied, the parameter is reduced by one to tighten the NMDT relaxation. Otherwise, the optimal solution of the NMDT relaxation is globally optimal for the original model.
4. Case Studies and Results
This section presents numerical simulations to validate the effectiveness of the FOR characterization method proposed in this paper. All programs are implemented in MATLAB R2024a and executed on a desktop computer equipped with 16 GB of memory and an Intel Core i5-10400F processor. All MILP problems are solved using Gurobi 12.0.1, and the feasible solutions for all NLP problems are obtained using IPOPT 3.14.17.
4.1. System Configuration
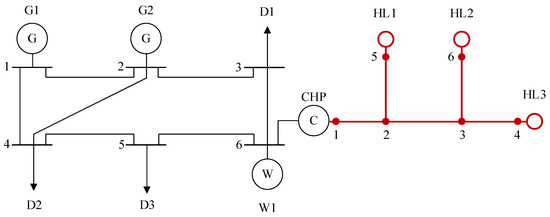
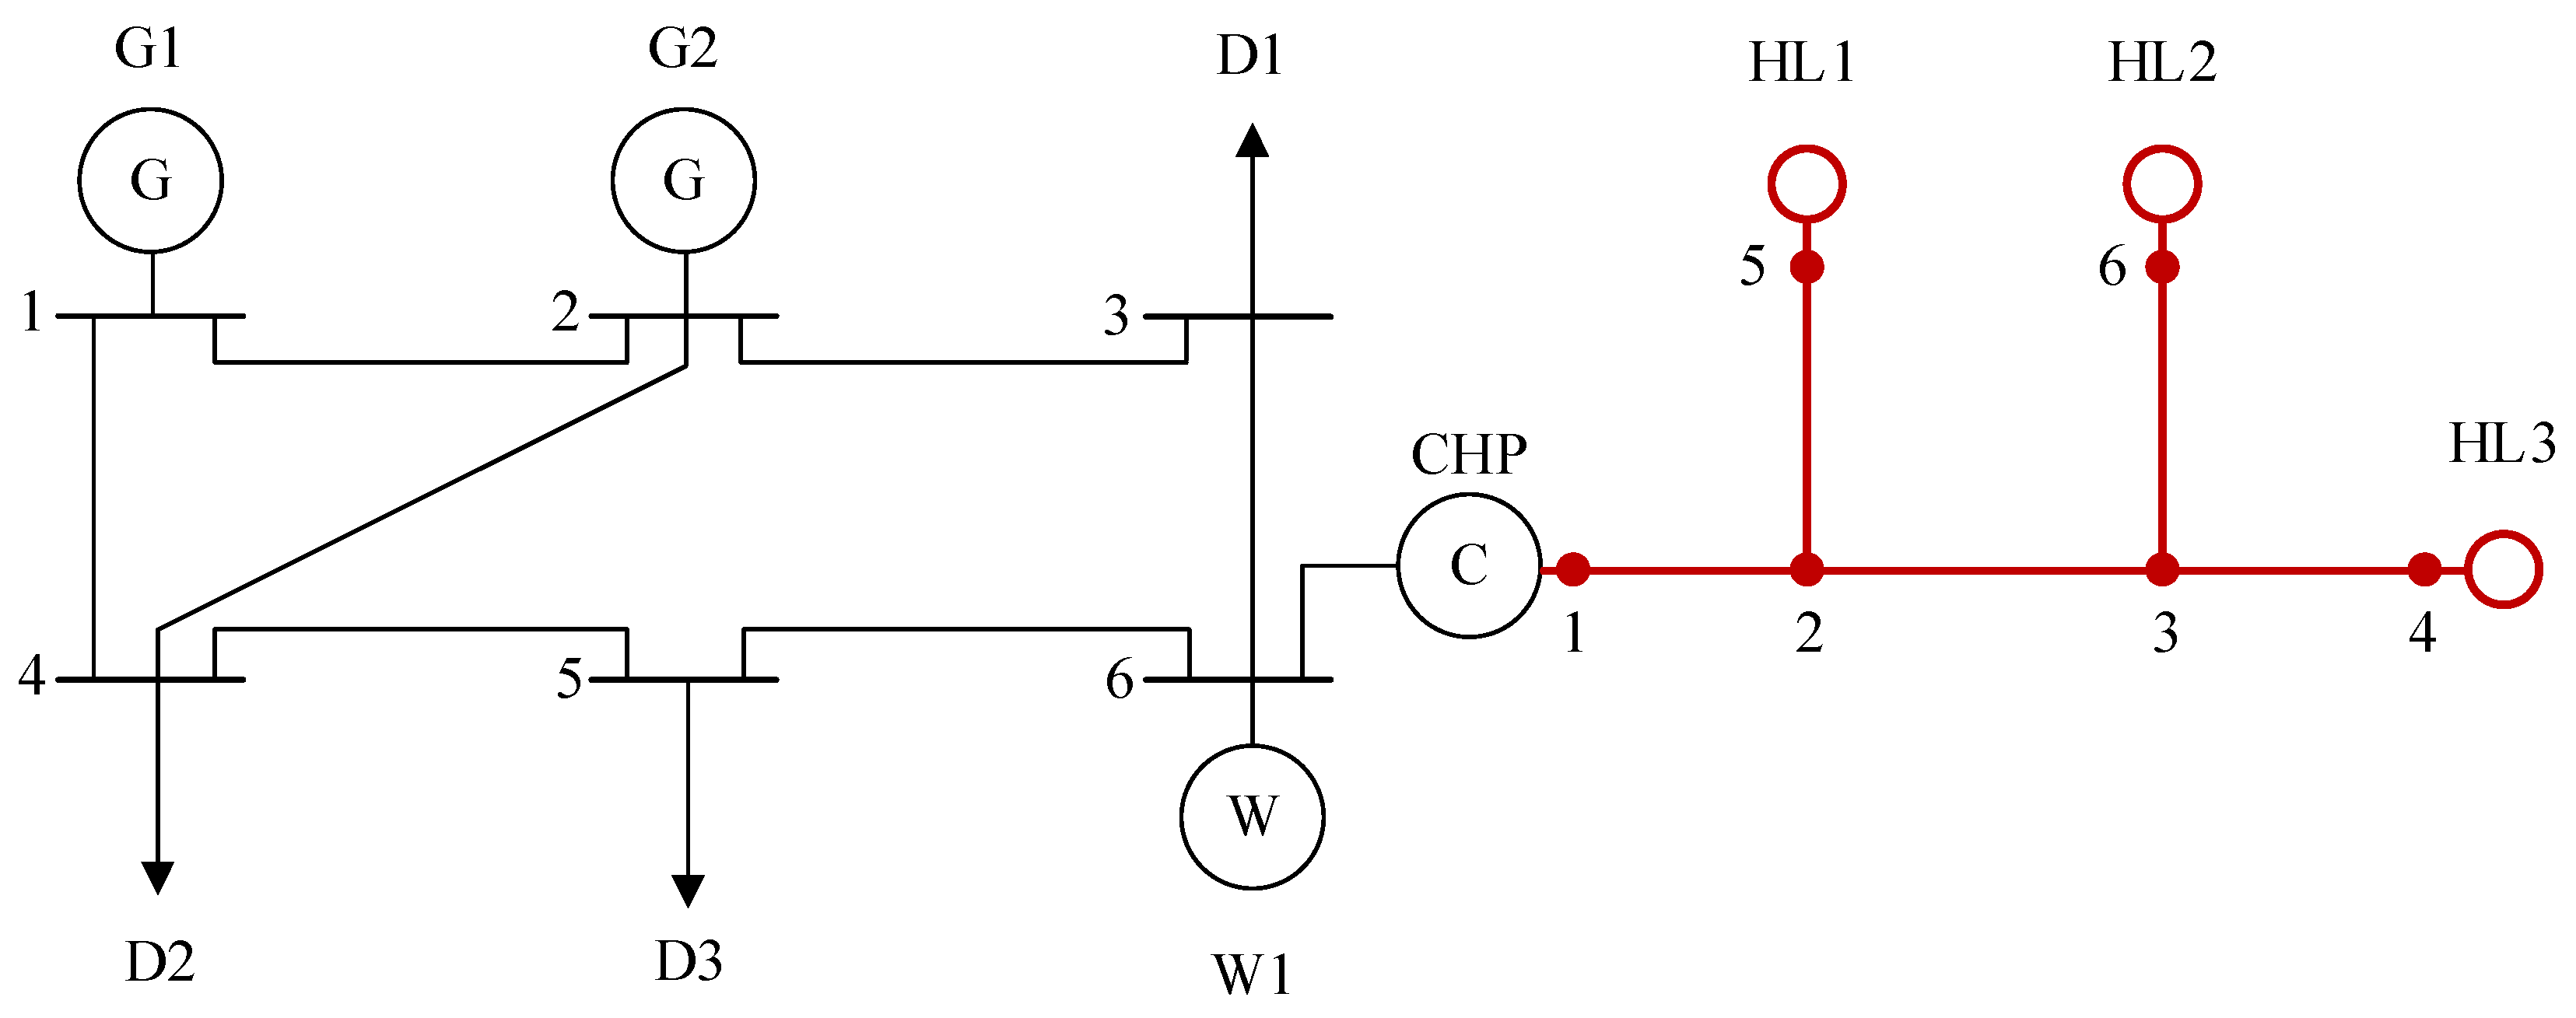
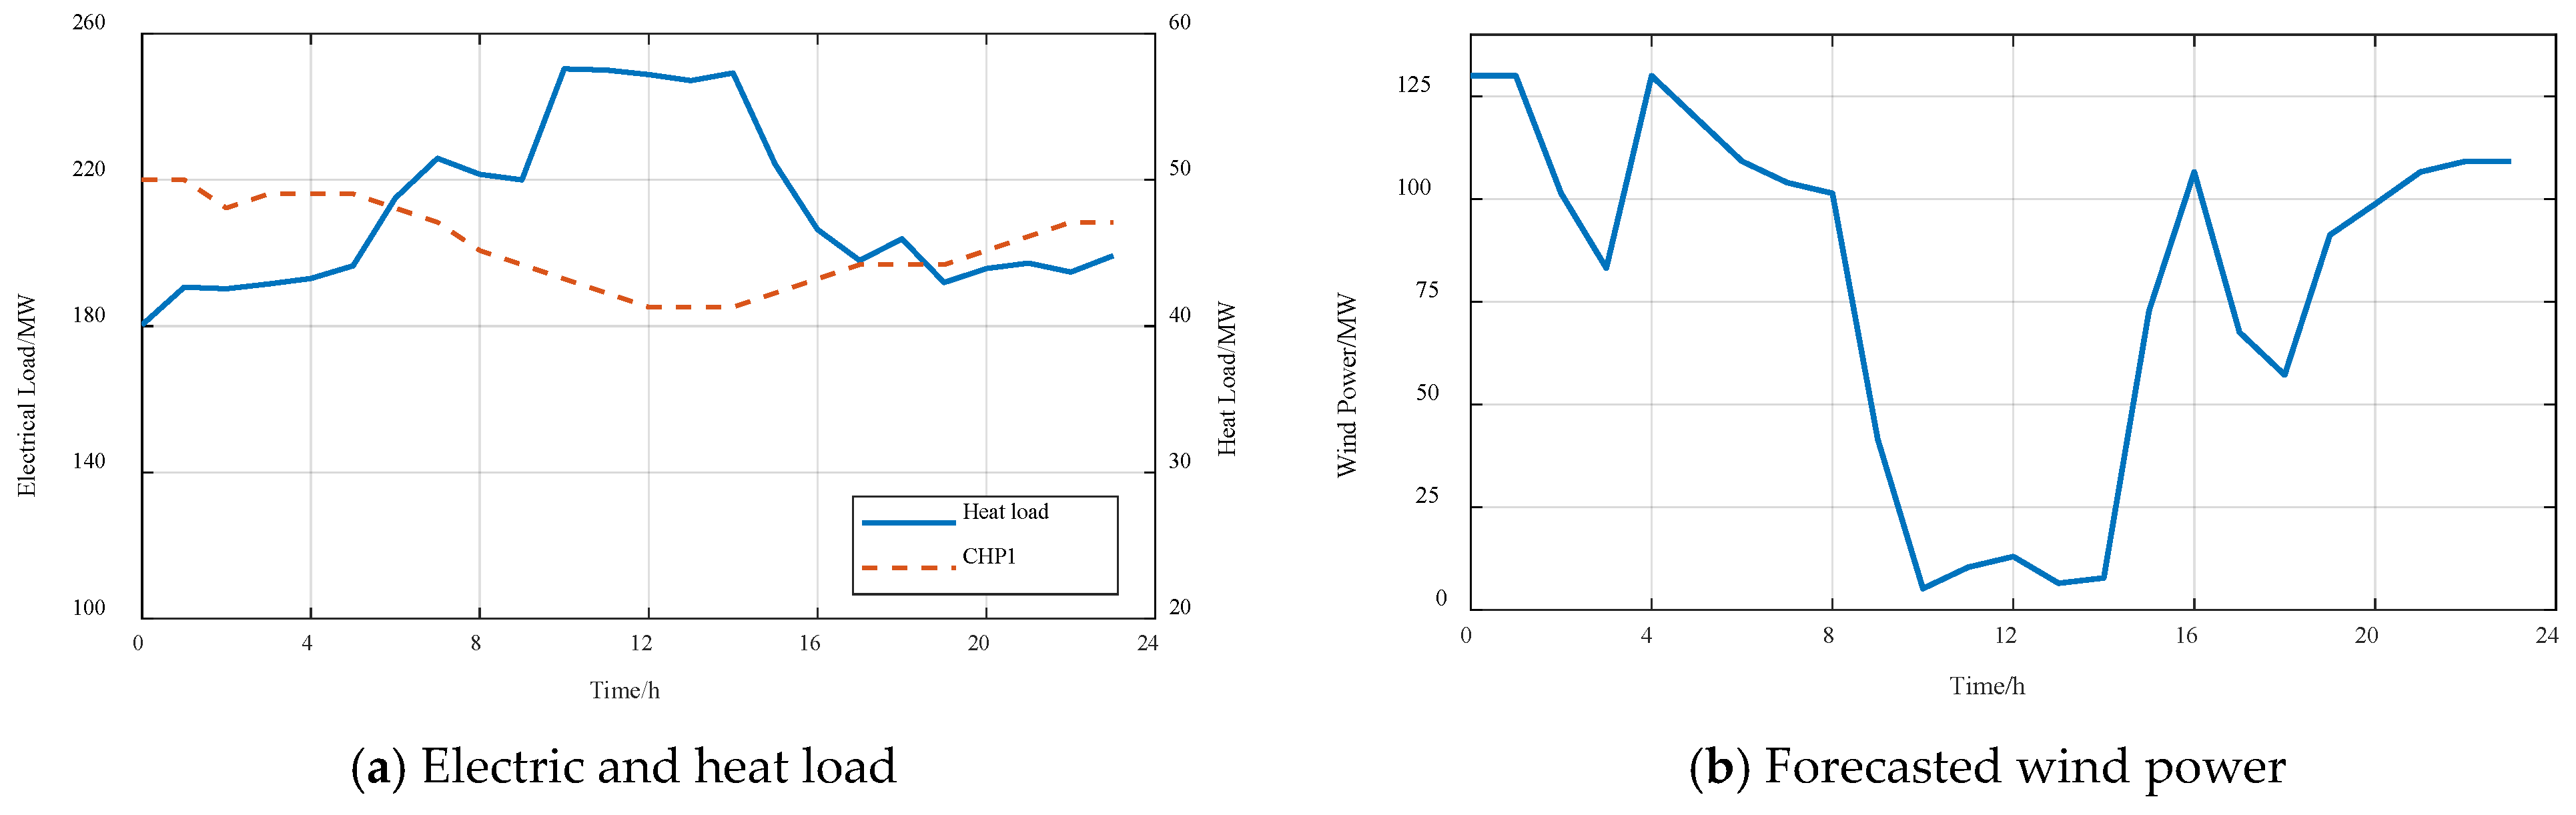
The test system consists of a six-bus EPS with wind power and a six-node DHS as shown in Figure 3. The EPS includes two thermal power generators, a back-pressure CHP unit, and one wind farm. The electric and heat loads of the IPHS are illustrated in Figure 4a, and the day-ahead forecast of the available power output of the wind farm is shown in Figure 4b. This paper focuses on a day-ahead combined heat and power dispatch, with a simulation time step of 1 h and a scheduling horizon of 24 h. The detailed system parameters are provided in [26].
Figure 3.
Diagram of 6-bus/6-node IPHS.
Figure 4.
Profiles of electric load, heat load, and forecasted wind power.
4.2. Method Validation
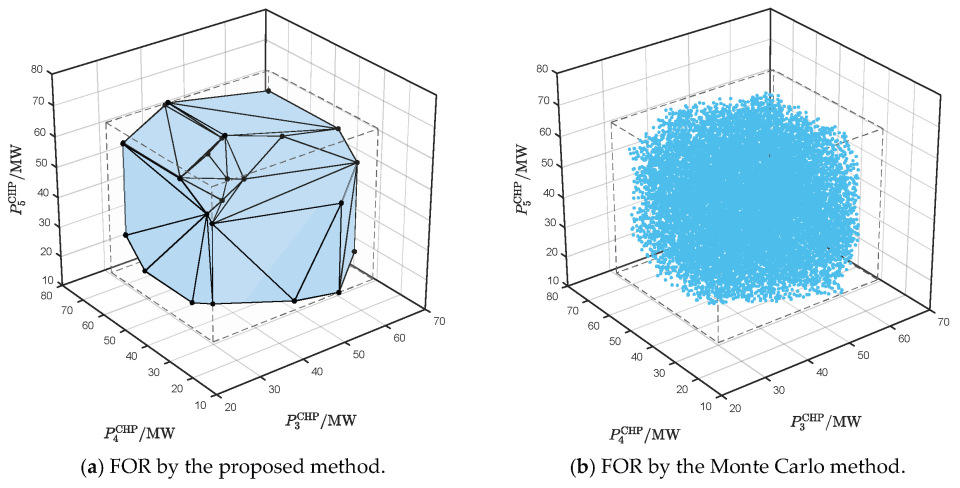
First, the effectiveness of the proposed method in characterizing the FOR of the DHS is validated. To construct a sufficiently large initial space, the maximum and minimum output of CHP at each dispatch period are computed, resulting in an initial space, Q, consisting of 48 rows of constraints. The three-dimensional FOR formed by the CHP at 3:00–4:00–5:00, as characterized by the proposed method, is illustrated in Figure 5a, where the initial space, Q, is shown as a cuboid outlined by gray dashed lines. For comparison, the FOR characterized by the Monte Carlo method is shown in Figure 5b.
Figure 5.
The three-dimensional FOR, characterized by the proposed method and the Monte Carlo method.
Figure 5b presents a Monte Carlo sampling-based point benchmark over the initial space Q. Specifically, 20,000 candidate samples are first drawn in Q and feasibility with respect to is then evaluated, yielding 14,737 feasible points that are used for visualization. Consistency between the benchmark and the proposed polyhedral representation is assessed by checking these 14,737 feasible points against ; it is confirmed that all 14,737 feasible points satisfy , indicating no violations of the polyhedral constraints on the sampled benchmark set. To quantify tightness, the relative gap between the sampled feasible set and each facet of is computed, based on the closest sampled point associated with that facet. The maximum relative gap across all facets reaches 0.73%, while the mean relative gap is 0.10%, indicating that the polyhedral boundary is tightly supported by the sampled feasible set and closely matches the benchmark region.
Next, combined heat and power dispatch is performed to verify the effectiveness of integrating the FOR model into IPHS operation. Three comparative operational frameworks are considered, as described below:
F1: The DHS operates in a heat-led mode, in which the heat output of the CHP strictly follows the heat load. In other words, the DHS cannot provide any flexibility to the EPS.
F2: The combined heat and power dispatch model employs the FOR obtained by the proposed method as the DHS constraints, i.e., model (21).
F3: The combined heat and power dispatch model directly integrates the detailed DHS model, i.e., model (17).
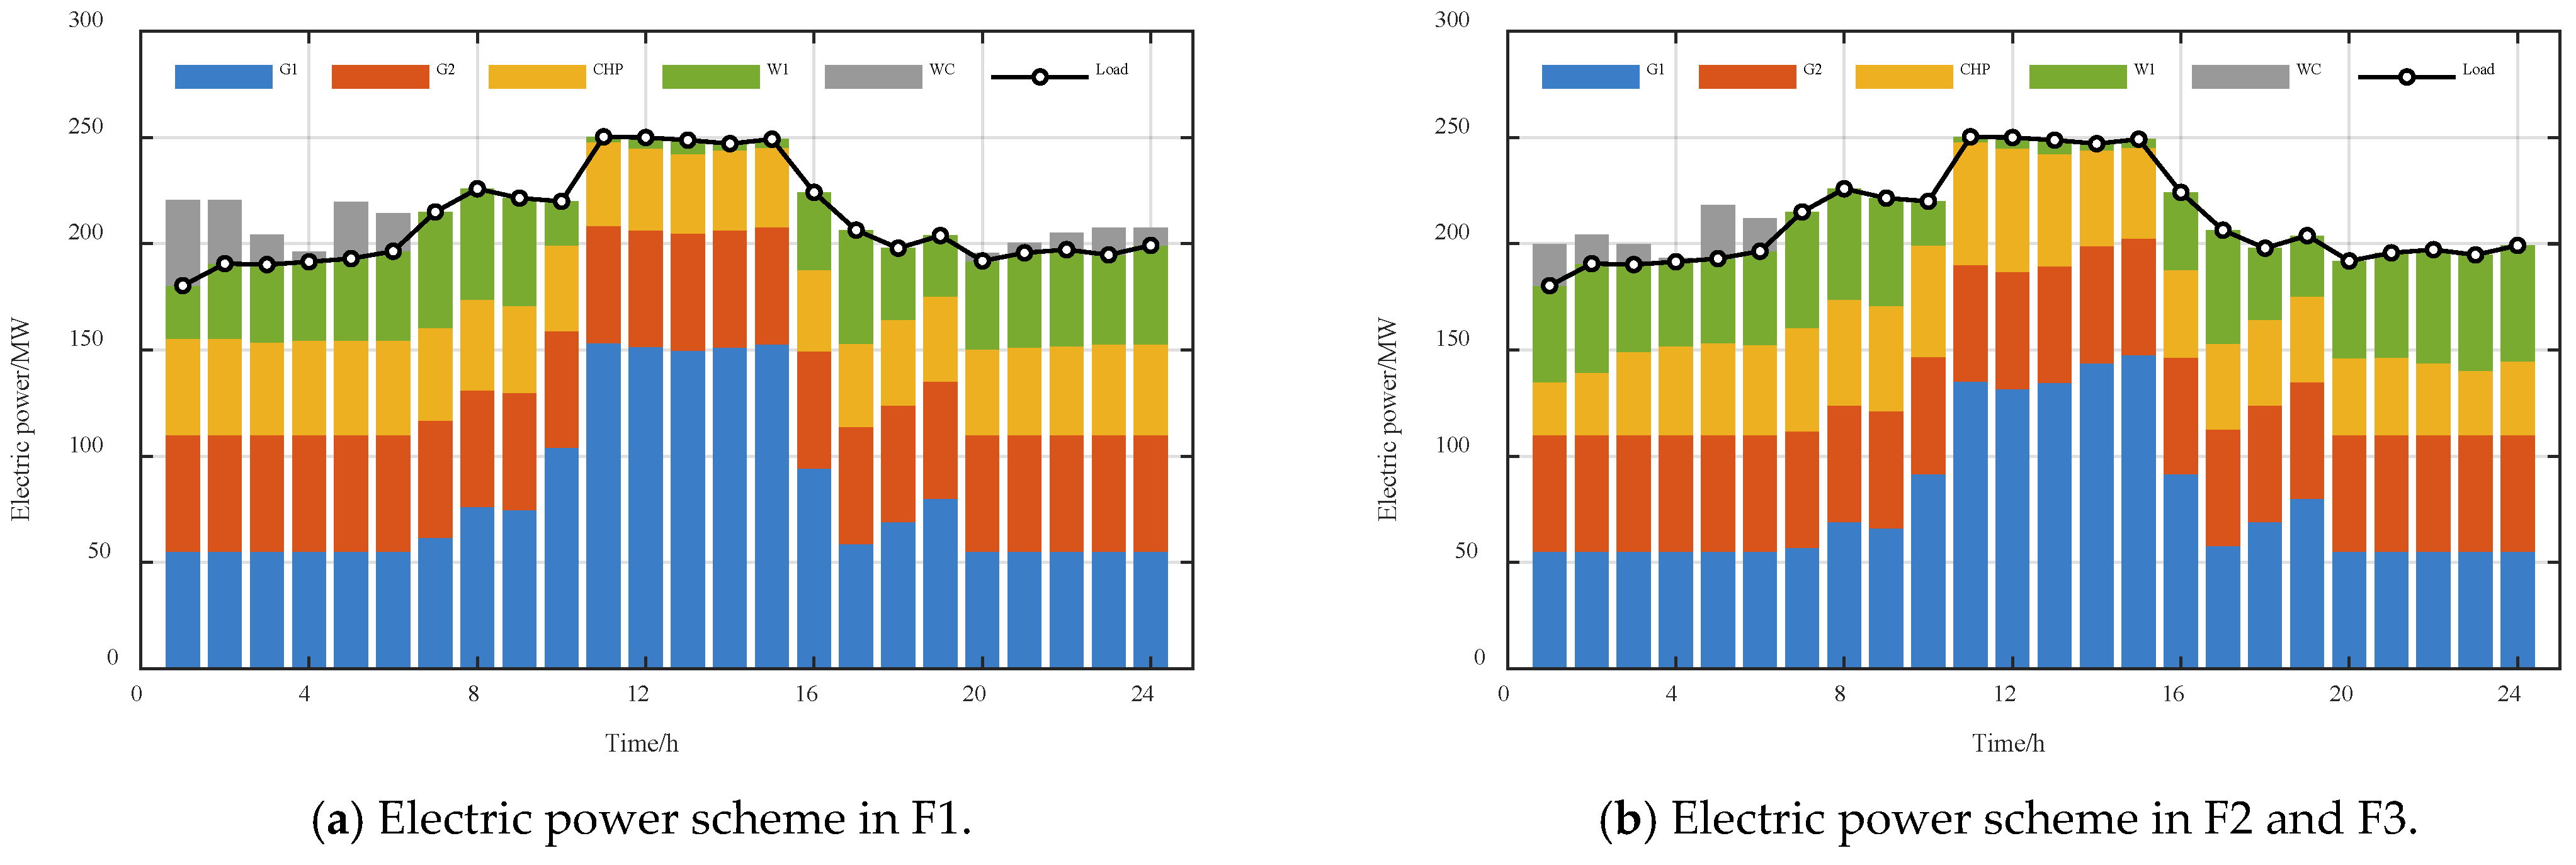
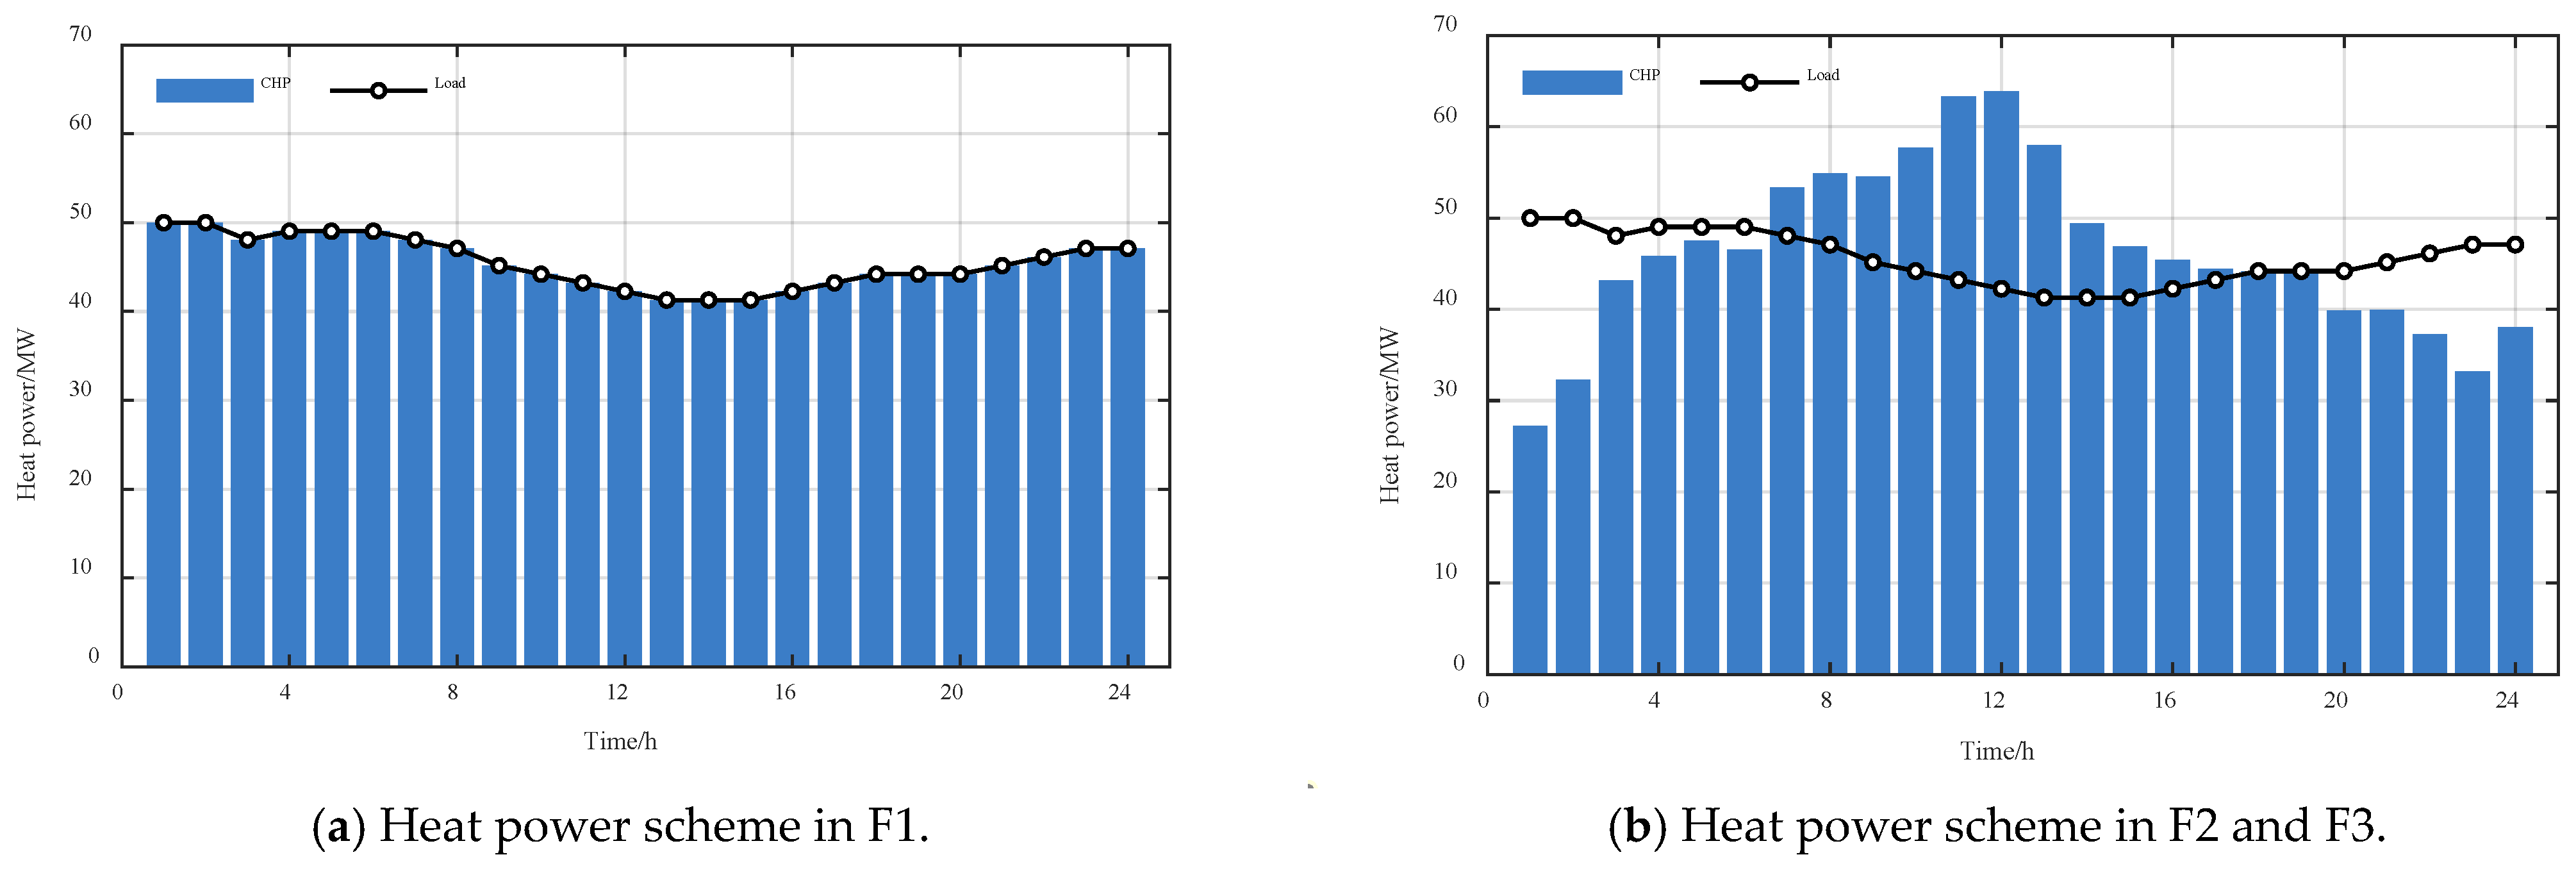
The scheduling schemes of the IPHS under the three frameworks are shown in Figure 6 and Figure 7. Figure 6a presents the EPS scheduling scheme for F1, where the gray bars indicate wind curtailment (WC). Because F2 and F3 employ equivalent scheduling models, they yield identical EPS schedules, as shown in Figure 6b. As observed from Figure 6, compared with F1, F2 fully exploits the flexibility of the DHS and improves wind power accommodation in the IPHS. Figure 7a shows the DHS scheduling scheme for F1, while Figure 7b depicts the DHS scheduling schemes for F2 and F3. As illustrated in Figure 7, reducing the CHP output in the morning and at noon creates additional room for wind power integration.
Figure 6.
Scheduling scheme of the EPS under different dispatch frameworks.
Figure 7.
Scheduling scheme of the DHS under different dispatch frameworks.
The scheduling results and computation times of the three frameworks are summarized in Table 1. Incorporating DHS flexibility into the combined heat and power dispatch reduces the total system generation cost by 1.62% and the curtailed wind energy by 49.9%. In addition, the computational efficiency of F2 surpasses that of F3 and is comparable to that of F1.
Table 1.
Scheduling results of the IPHS under different operation frameworks.
4.3. Scalability and Parameter Sensitivity Analysis
Table 2 and Table 3 summarize the computational efficiency of the proposed method; each case is evaluated independently in ten runs. Table 2 shows that the practical-scale DHS benchmarks with 32 nodes [27] and 61 nodes [28] satisfy the efficiency criteria, demonstrating the scalability of the proposed approach. Table 3 compares the runtime for the FOR quantification on the 32-node DHS under different scheduling-horizon lengths. The results indicate that the computational burden is more sensitive to the number of scheduling horizons—that is, the dimension of the projected polyhedral space—than to other factors. Overall, the proposed method is sufficiently efficient to meet the day-ahead scheduling requirements of practical-scale DHSs at an hourly resolution. In contrast, adopting a finer temporal resolution would substantially increase the dimension of , thereby degrading the computational efficiency.
Table 2.
FOR computation time for DHS benchmarks of different sizes.
Table 3.
FOR computation time for DHS benchmarks of different scheduling horizons.
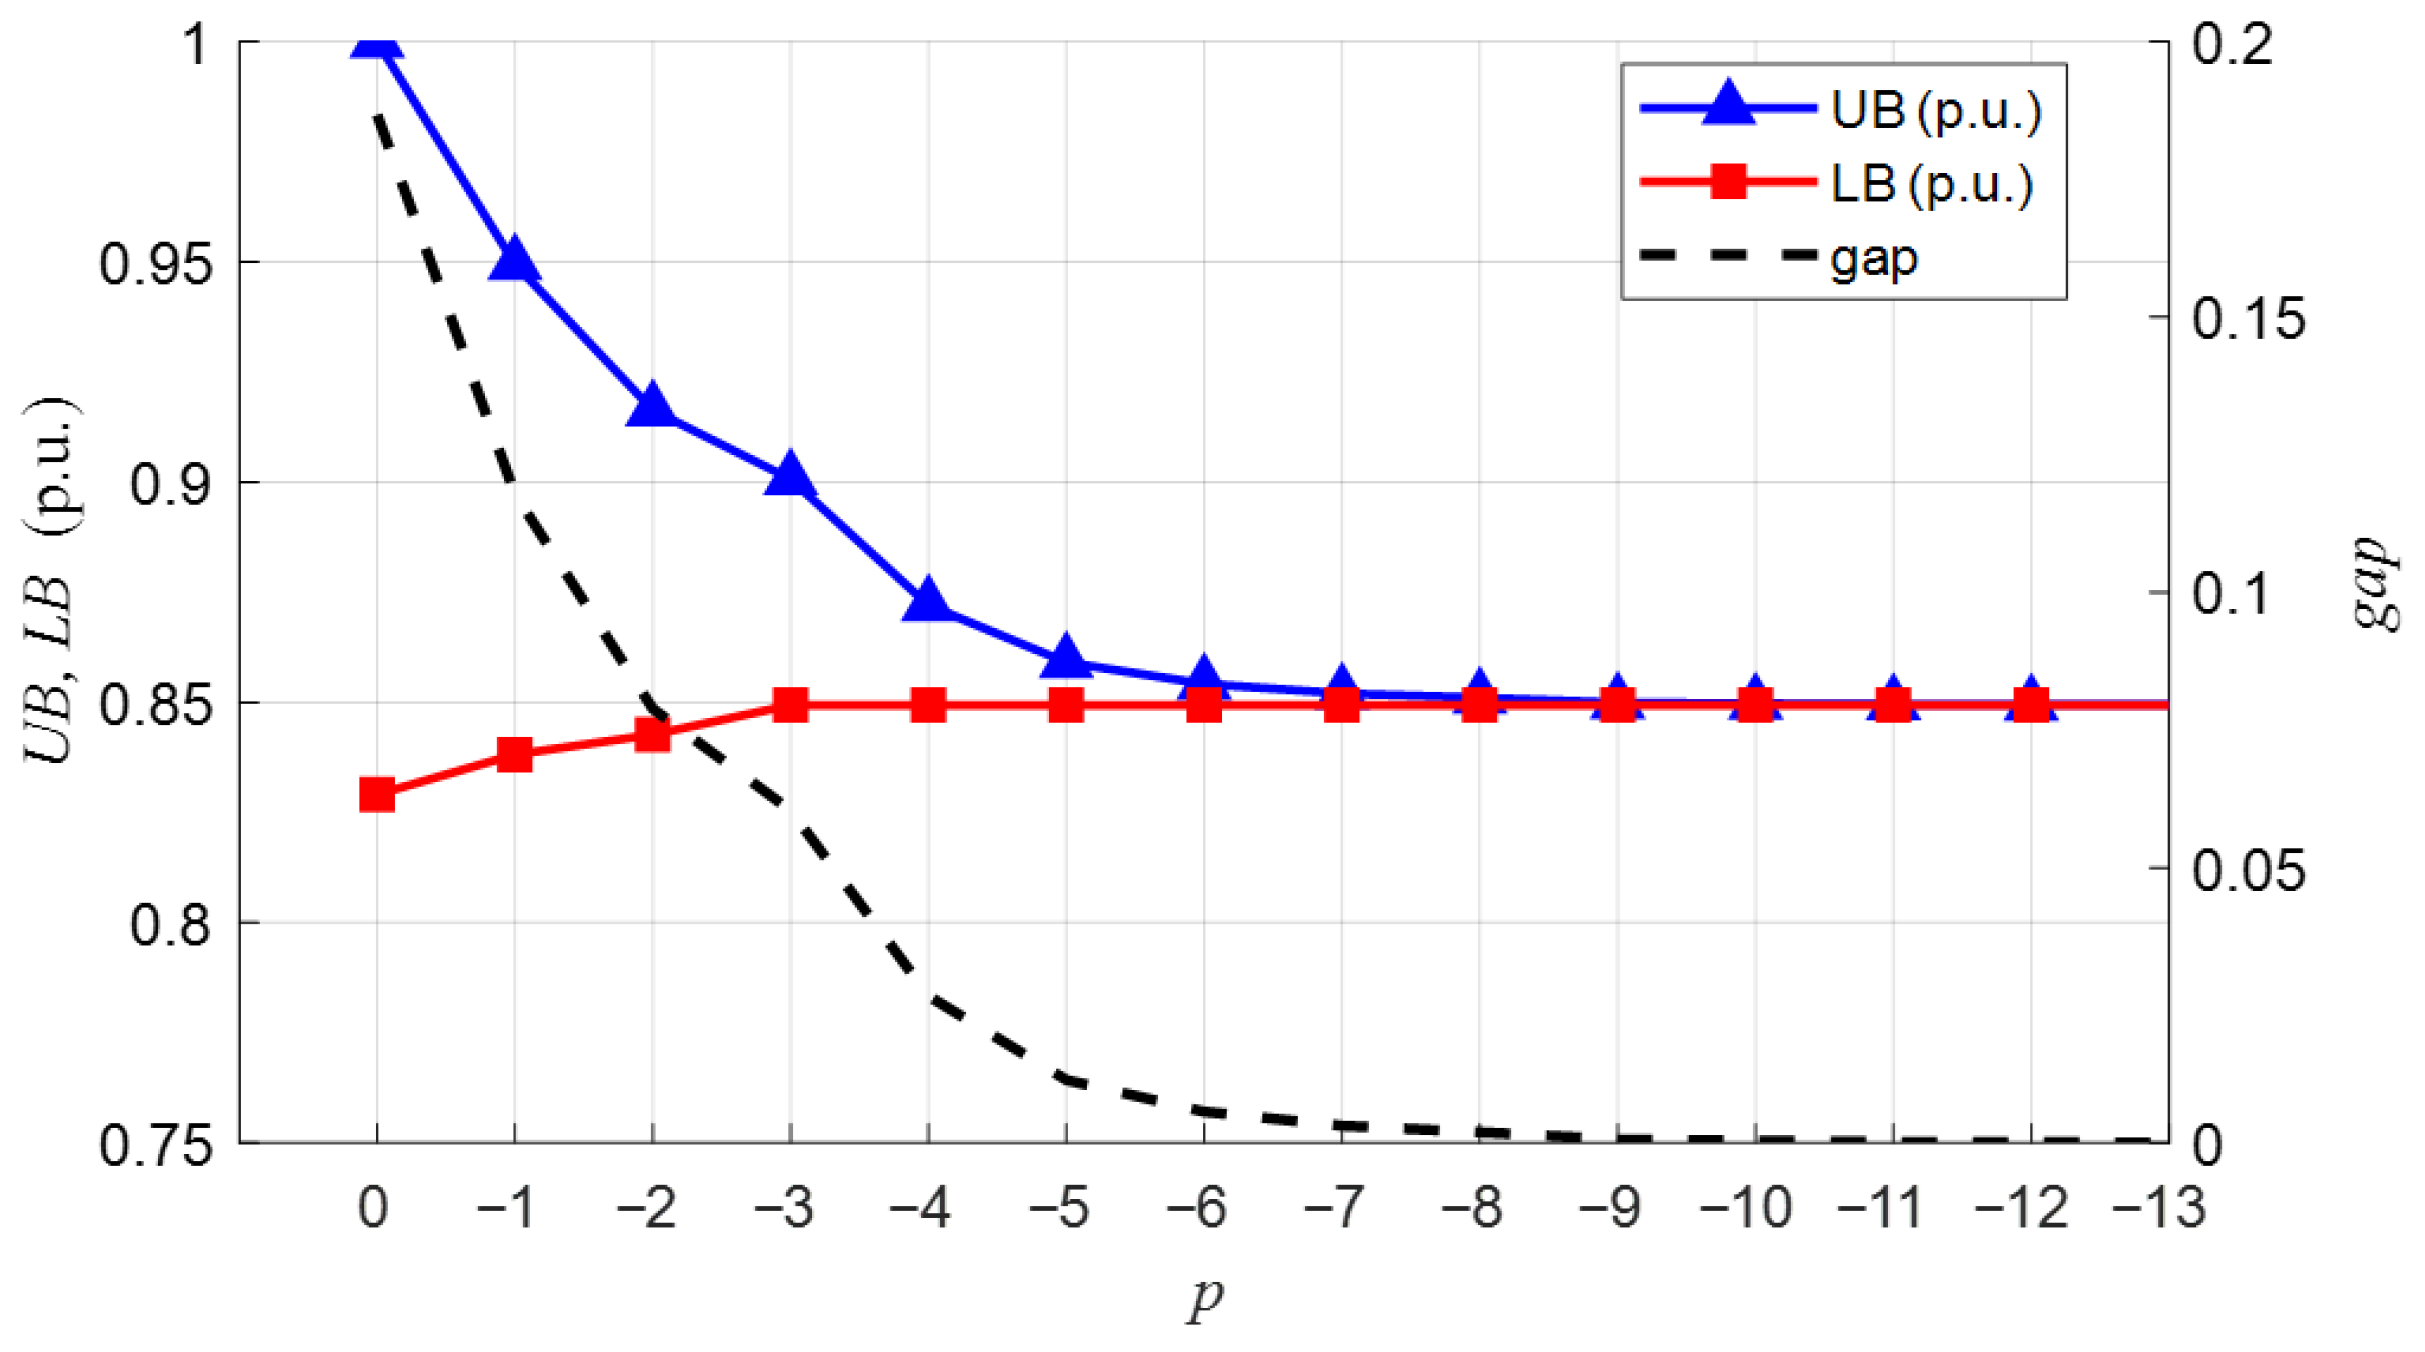
Figure 8 illustrates the convergence behavior of the inner loop of the proposed algorithm. As the discretization is progressively refined, we track the UB obtained from the NMDT relaxation, the LB provided by feasible solutions, and their relative optimality gap. The results in Figure 8 indicate that gradually refining the discretization improves the approximation quality of the relaxation to the original bilinear problem, thereby simultaneously tightening both UB and LB and driving global convergence. It is worth emphasizing that, in our framework, p solely controls the refinement level of the discretization, whereas ε is the termination tolerance used to determine whether the current UB–LB gap is sufficiently small. Once the relative gap falls below ε, the obtained solution can be regarded as an ε-global optimum of the original problem under the specified tolerance. Moreover, the convergence trend suggests that further refinement yields only marginal improvements in the objective value once the gap becomes sufficiently small, while the computational complexity increases substantially with finer discretization. Balancing solution accuracy and computational efficiency, we set ε = 0.001, which achieves stable convergence within a limited number of refinement steps and provides a reliable approximation for global optimality.
Figure 8.
Convergence behavior of the inner loop of the proposed algorithm.
4.4. Analysis of DHS Flexibility
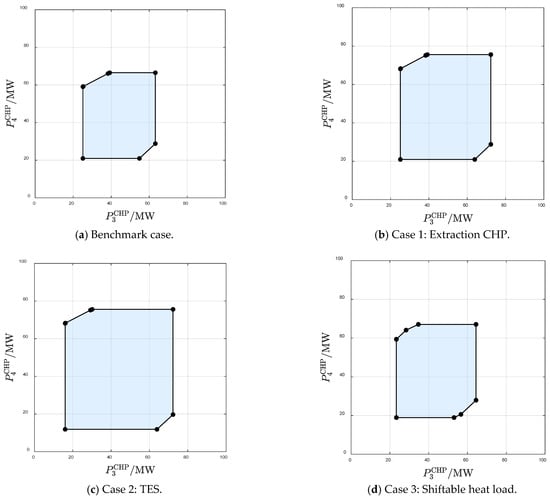
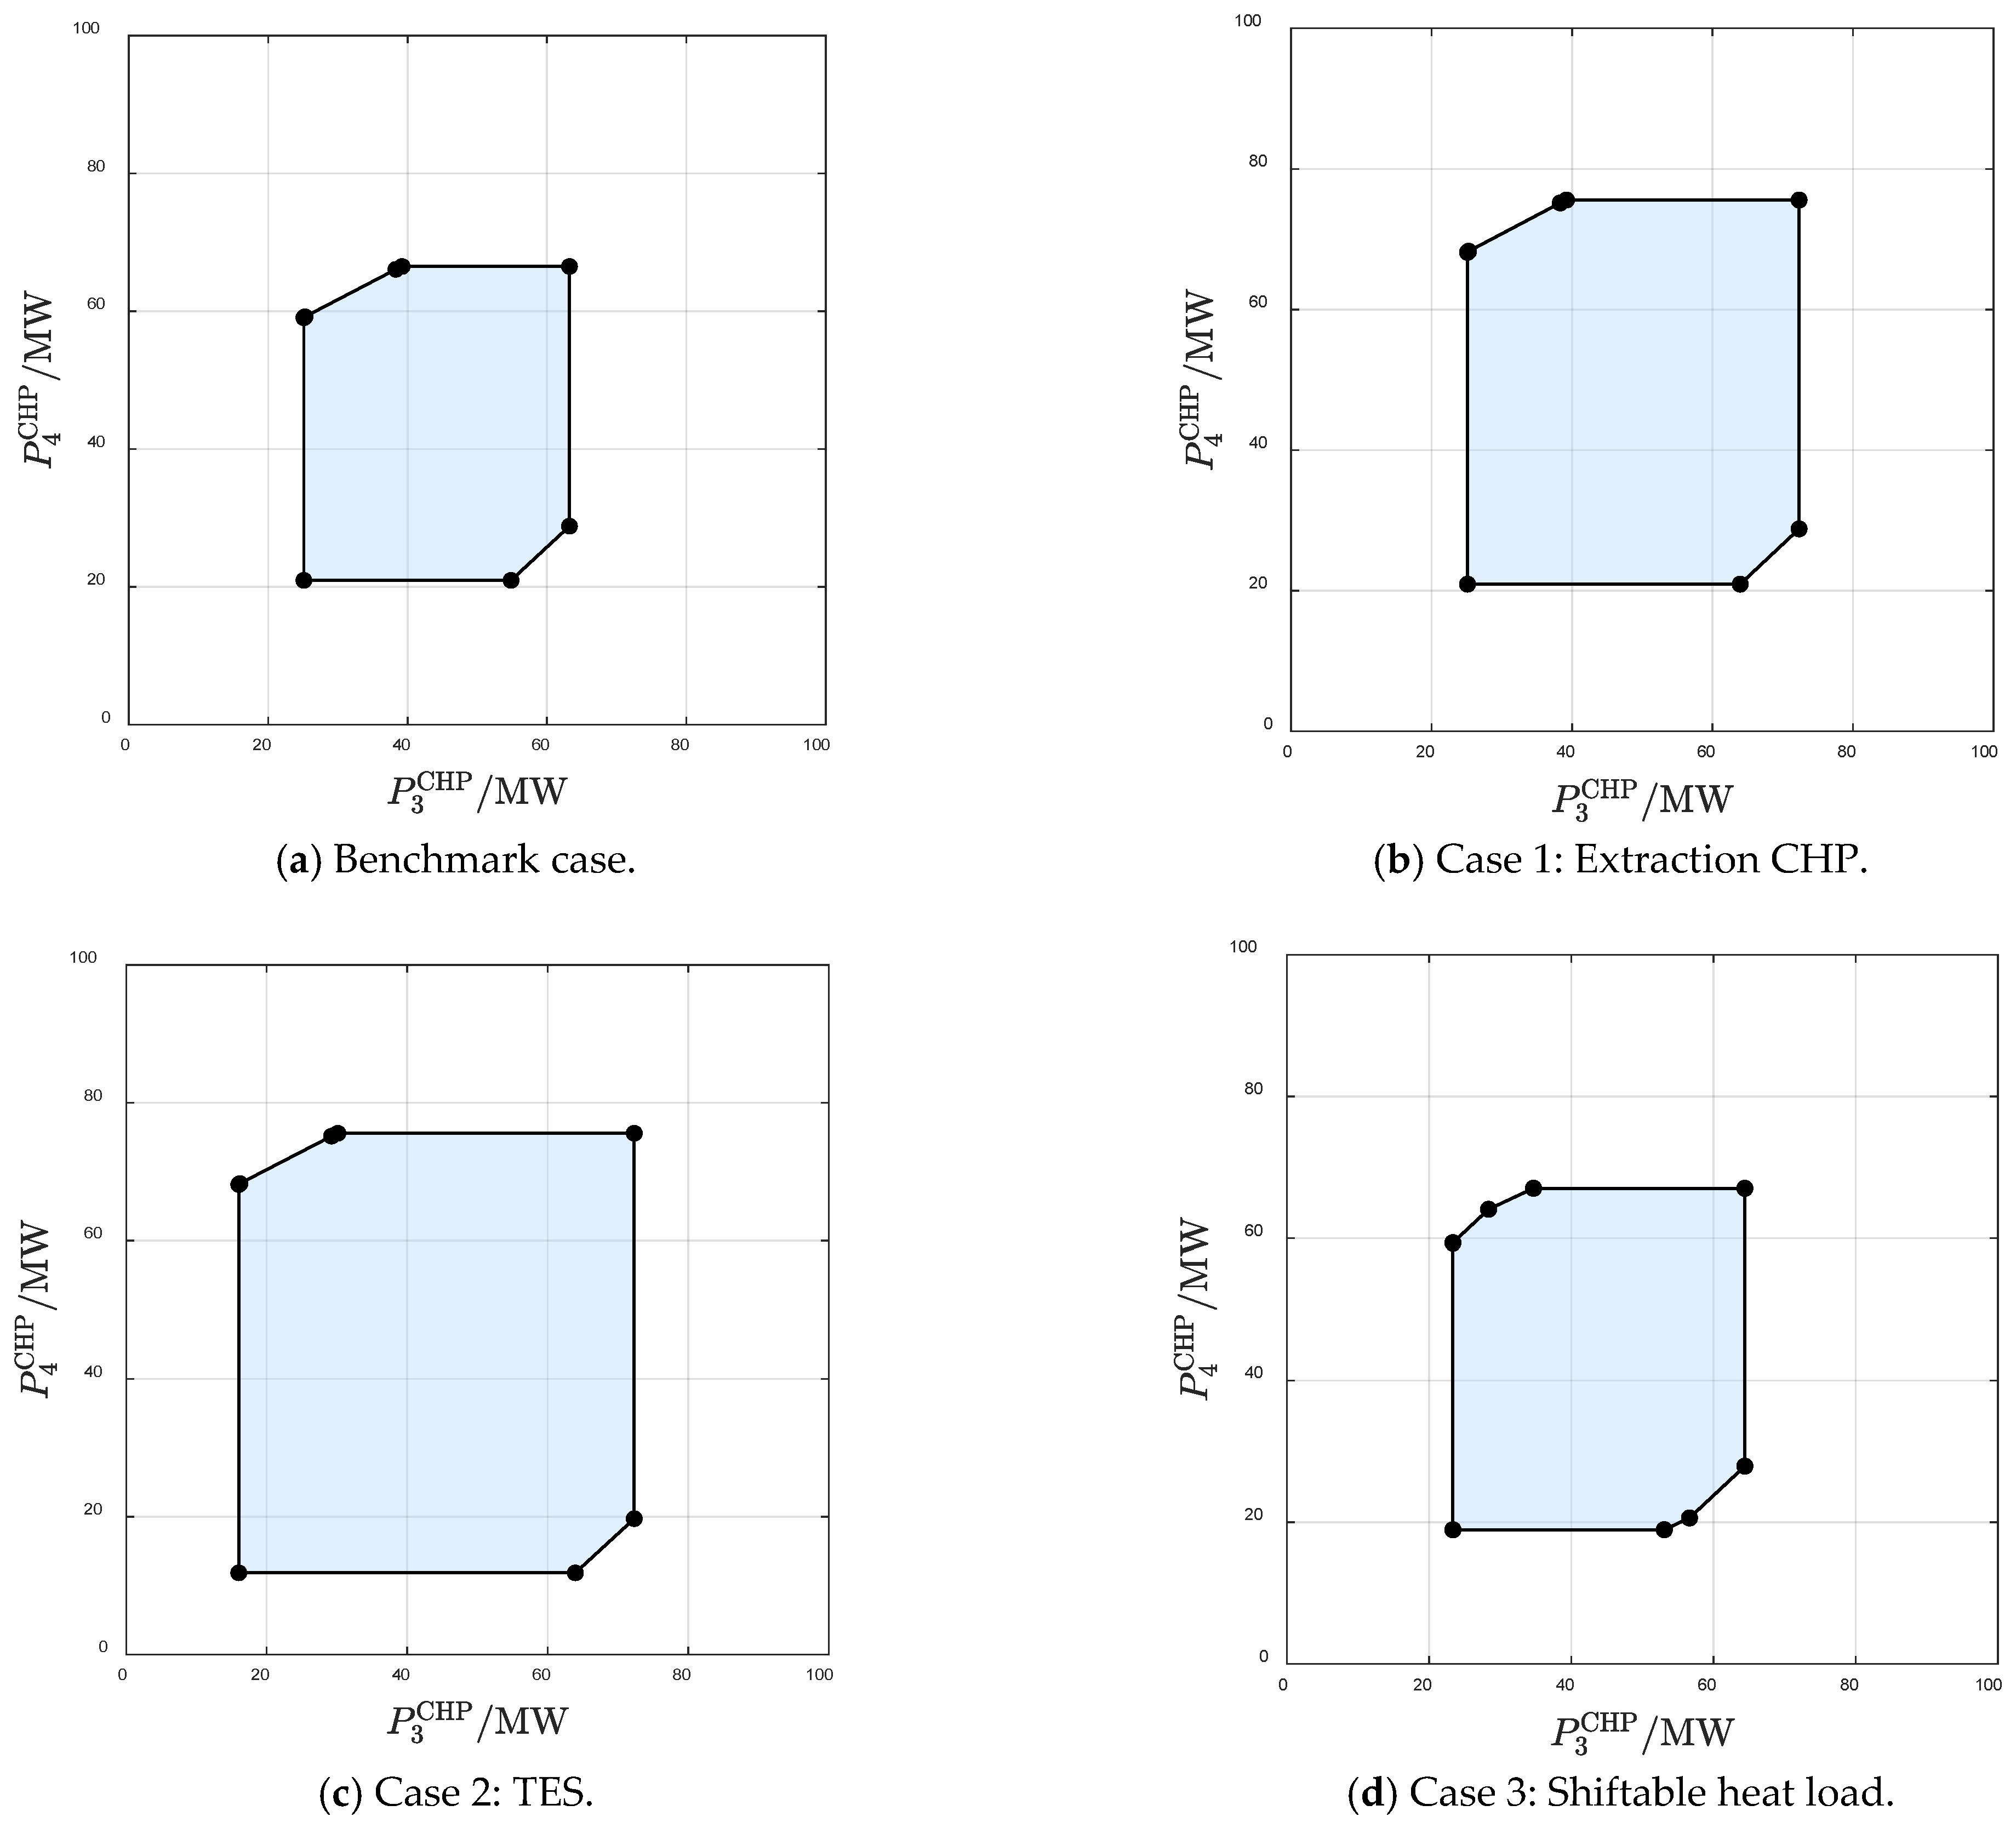
In this section, the factors influencing DHS flexibility are analyzed using the FOR framework. The two-dimensional FORs corresponding to the CHP at 03:00–04:00 are shown in Figure 9 and Figure 10. Figure 9 examines the impact of different DHS components on flexibility. In Case 1, the CHP is replaced by an extraction CHP, which increases its upward flexibility, as shown in Figure 9b. In Case 2, the heat source is equipped with a TES device, providing both upward and downward flexibility. As shown in Figure 9c, the FOR expands in all directions. In Case 3, 5% of the heat load is assumed to be shiftable, leading to a slight increase in both upward and downward DHS flexibility, as illustrated in Figure 9d.
Figure 9.
The two-dimensional FOR, considering different DHS components.
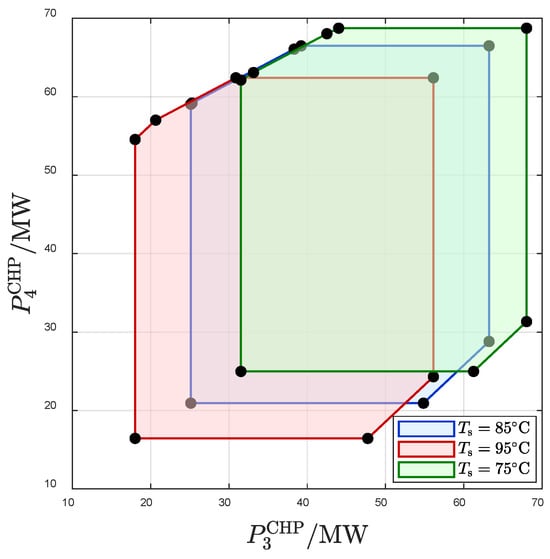
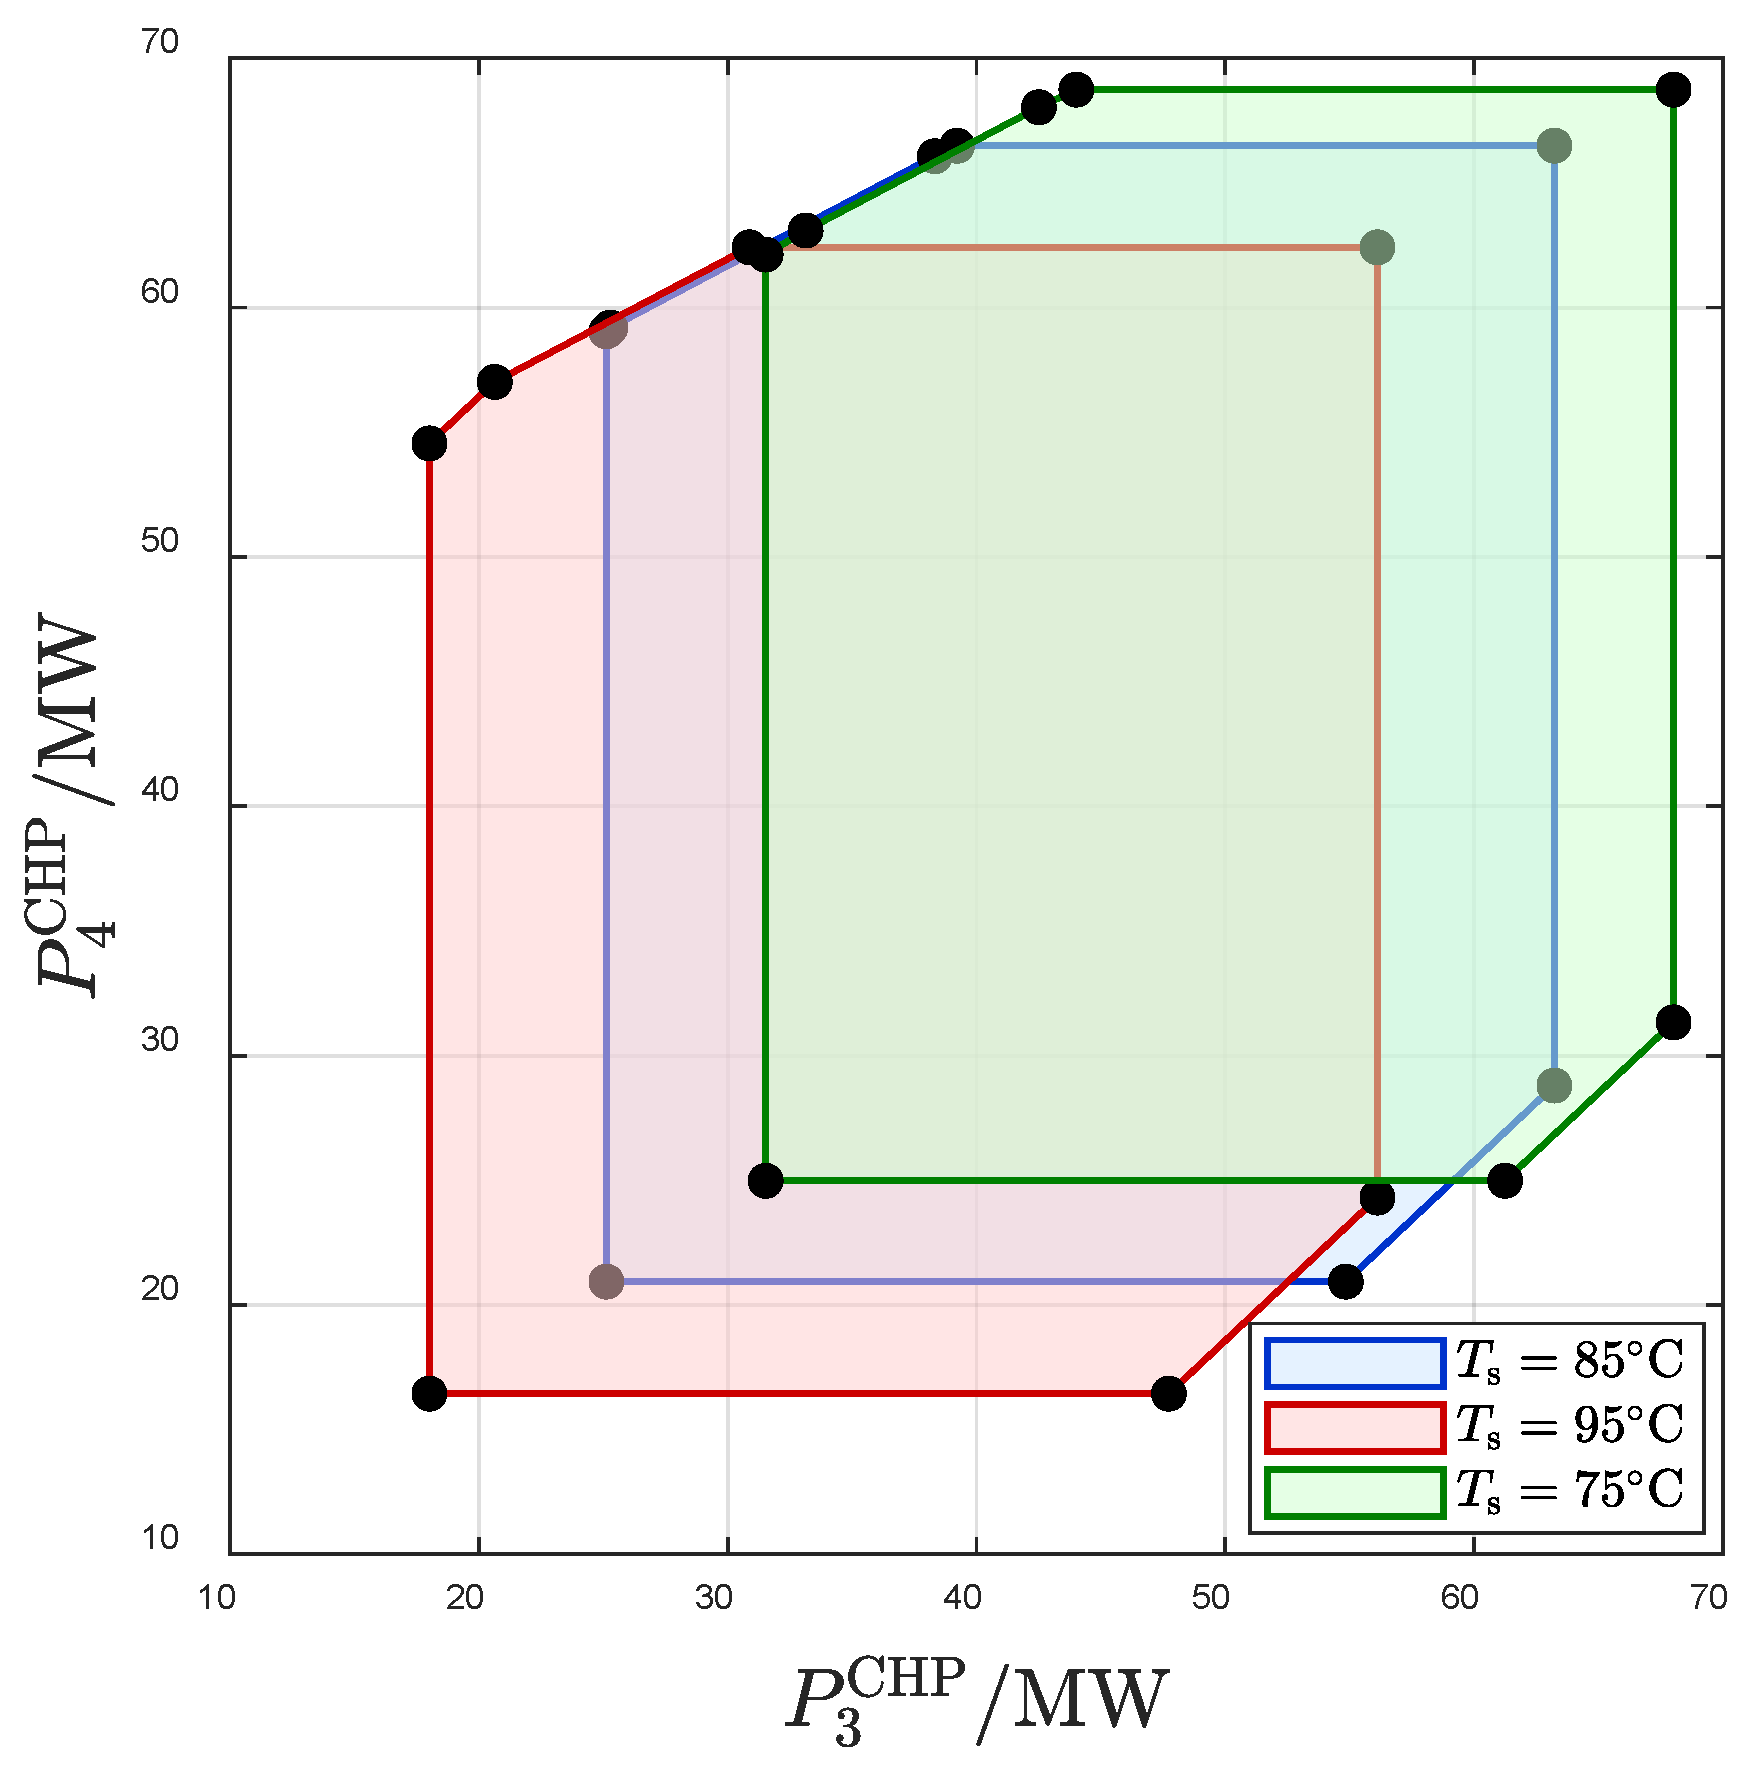
Figure 10.
The two-dimensional FOR, considering different supply temperatures.
Next, the impact of the supply temperature on DHS flexibility is investigated. Figure 10 shows the FORs corresponding to supply temperatures of 75 °C, 85 °C, and 95 °C. When the supply temperature is relatively low, the average water temperature in the pipeline network is also low, indicating that the DHS has potential to provide additional upward flexibility. As seen in Figure 10, the FOR at 75 °C offers a larger upward adjustment margin for the CHP. Conversely, when the supply temperature is relatively high, the water temperature in the pipeline network approaches its upper limit, implying that the thermal storage capacity of the network is highly utilized. In this case, the CHP has greater downward flexibility, which is beneficial for wind power accommodation. The scheduling results and wind power accommodation for these cases are summarized in Table 4. As shown in Table 4, wind curtailment decreases as the supply temperature increases, which is consistent with the FOR characteristics in Figure 10.
Table 4.
Scheduling results of the IPHS under different supply temperatures.
5. Conclusions
This paper develops a FOR approach for characterizing the flexibility of the coordinated operation between the DHS and the EPS. The proposed method reformulates the DHS constraints into a compact linear form and defines the FOR as a polyhedral projection in the space of coupling variables. A FCOAA-based method is proposed, which iteratively removes infeasible operating points and constructs an explicit description of feasible cuts to obtain the FOR. To handle the bilinear terms in the feasible-cut generation model, a global optimization strategy based on the NMDT is introduced, reformulating the problem as an MILP problem with controllable relaxation accuracy. The resulting FOR constraints depend only on the coupling variables and can be directly embedded into the IPHS scheduling model without disclosing the internal states of the DHS.
Numerical simulations on an IPHS with a 6-bus EPS and a 6-node DHS are conducted to validate the proposed method. The three-dimensional FOR obtained by the FCOAA-based method closely matches the Monte Carlo benchmark results, while providing explicit and optimization-friendly boundary representations. When the FOR-based DHS model is used for IPHS scheduling, the resulting dispatch is consistent with that of a detailed DHS model, but with a significantly reduced solution time. Parametric analysis of the FOR further clarifies how the type of CHPs, TES devices, shiftable heat load, and supply-water temperature affect the system’s flexibility and wind-power accommodation.
Future work will consider extending the framework to IPHS composed of a DHS with practical size.
Author Contributions
Conceptualization, H.Z. and H.L.; methodology, H.Z. and H.L.; software, H.Z.; validation, H.Z., Y.Z. and J.Z.; formal analysis, H.Z. and R.L.; investigation, H.Z. and Y.Z.; resources, H.L.; data curation, H.Z. and J.Z.; writing—original draft preparation, H.Z. and R.L.; writing—review and editing, H.Z. and H.L.; visualization, H.Z. and J.Z.; supervision, H.L.; project administration, H.L.; funding acquisition, H.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the Science and Technology Foundation of State Grid Jilin Electric Power System Company (2022JBGS-04).
Data Availability Statement
The data required for this article are listed in Figure 3 and Reference [26].
Conflicts of Interest
Authors Haifeng Zhang, Yifu Zhang, Jiajun Zhang and Runzi Lin are employed in Jilin Electric Power Research Institute. The authors declare no conflicts of interest.
Nomenclature
| Abbreviations | |
| DHS | District heating system |
| EPS | Electrical power system |
| IPHS | Integrated power and heat system |
| FOR | Flexible operation region |
| FCOAA | Farkas-cut outer approximation algorithm |
| NMDT | Normalized multiparametric disaggregation technique |
| MILP | Mixed-integer linear programming |
| TES | Thermal energy storage |
| CHP | Combined heat and power |
| Indices | |
| g | Index of generation/CHP/thermal/wind unit |
| t | Index of time period |
| l | Index of pipeline/power line |
| n | Index of DHS node |
| k | Index of electrical load |
| i, j | Indices of bilinear-term variables in relaxation |
| q | Index of bit position in binary expansion |
| Sets | |
| Set of all CHP units | |
| Set of all thermal power units | |
| Set of all wind farms | |
| Set of all power generation units | |
| Set of all electrical power loads | |
| Set of heat-load nodes | |
| Set of mixing nodes | |
| Set of pipelines | |
| Set of outflow pipelines associated with node n | |
| Set of inflow pipelines associated with node n | |
| Set of all bilinear terms in the model | |
| Set of variables to be discretized | |
| Exponent index set in binary expansion | |
| Variables | |
| Heat output of CHP unit g at period t | |
| Power output of CHP unit g at period t | |
| Heat-to-power ratio of CHP unit g | |
| Power output of thermal power unit g at period t | |
| Power output of wind farm g at period t | |
| Available upward/downward reserve capacity of unit g at period t | |
| Inlet/outlet temperature of supply pipeline l at period t | |
| Inlet/outlet temperature of return pipeline l at period t | |
| Average temperature of supply/return pipeline l at period t | |
| Coupling variables of DHS | |
| State variables of DHS | |
| Farkas vector used in cut generation | |
| to be disaggregated | |
| to be discretized | |
| in NMDT | |
| Parameters | |
| Specific heat capacity of the thermal energy carrier | |
| Mass flow rate of pipeline l at period t | |
| Density of the thermal energy carrier | |
| Time step of combined heat and power dispatch | |
| Outdoor temperature at time t | |
| Length of pipeline l | |
| Inner diameter of pipeline l | |
| Heat loss coefficient of pipeline l | |
| Heat demand of heat load n at period t | |
| Power demand of electrical load k at period t | |
| Capacity of power line l | |
| Generator/load-related PTDF parameter for line l | |
| Upward/downward reserve demand at period t | |
| Penalty factor for wind power curtailment | |
| Generation cost function of thermal power units | |
| Generation cost function of CHP units | |
| Min/max power output limits of CHP unit g | |
| Upward/downward ramping limits of CHP unit g | |
| Min/max power output limits of thermal power unit g | |
| Upward/downward ramping limits of thermal power unit g | |
| Maximum available wind power output of wind farm g at period t | |
| Number of time periods | |
| Constant vector in compact DHS constraints | |
| Matrix/vector describing projected FOR | |
| Matrix/vector describing initial space | |
| Discretization accuracy in NMDT | |
References
- Hadi, M.B.; Moeini-Aghtaie, M.; Khoshjahan, M.; Dehghanian, P. A comprehensive review on power system flexibility: Concept, services, and products. IEEE Access 2022, 10, 99257. [Google Scholar] [CrossRef] [Scilit]
- Kaushik, E.; Prakash, V.; Mahela, O.P.; Khan, B.; El-Shahat, A.; Abdelaziz, A.Y. Comprehensive overview of power system flexibility during the scenario of high penetration of renewable energy in utility grid. Energies 2022, 15, 516. [Google Scholar] [CrossRef] [Scilit]
- Tan, J.; Wu, Q.; Hu, Q.; Wei, W.; Liu, F. Adaptive robust energy and reserve co-optimization of integrated electricity and heating system considering wind uncertainty. Appl. Energy 2020, 260, 114230. [Google Scholar] [CrossRef] [Scilit]
- Zhang, M.; Wu, Q.; Wen, J.; Lin, Z.; Fang, F.; Chen, Q. Optimal operation of integrated electricity and heat system: A review of modeling and solution methods. Renew. Sustain. Energy Rev. 2021, 135, 110098. [Google Scholar] [CrossRef] [Scilit]
- Kuosa, M.; Kiviranta, P.; Sarvelainen, H.; Tuliniemi, E.; Korpela, T.; Tallinen, K.; Koponen, H.-K. Optimisation of district heating production by utilising the storage capacity of a district heating network on the basis of weather forecasts. Results Eng. 2022, 13, 100318. [Google Scholar] [CrossRef] [Scilit]
- Ochs, F.; Dahash, A.; Tosatto, A.; Janetti, M.B. Techno-economic planning and construction of cost-effective large-scale hot water thermal energy storage for renewable district heating systems. Renew. Energy 2020, 150, 1165–1177. [Google Scholar]
- Lim, T.; Yim, W.-S.; Kim, D.-D. Analysis of the thermal and cooling energy performance of the perimeter zones in an office building. Buildings 2022, 12, 141. [Google Scholar] [CrossRef] [Scilit]
- Yu, P.; Li, D.; Cui, D.; Xu, J.; Li, C.; Cao, H. Coordinated scheduling and operational characterization of electricity and district heating systems: A case study. Energies 2025, 18, 2211. [Google Scholar] [CrossRef] [Scilit]
- Pan, Z.; Guo, Q.; Sun, H. Feasible region method based integrated heat and electricity dispatch considering building thermal inertia. Appl. Energy 2017, 192, 395–407. [Google Scholar] [CrossRef] [Scilit]
- Jiang, Y.; Wan, C.; Botterud, A.; Song, Y.; Xia, S. Exploiting flexibility of district heating networks in combined heat and power dispatch. IEEE Trans. Sustain. Energy 2020, 11, 2174–2188. [Google Scholar] [CrossRef] [Scilit]
- Xu, X.; Lyu, Q.; Qadrdan, M.; Wu, J. Quantification of flexibility of a district heating system for the power grid. IEEE Trans. Sustain. Energy 2020, 11, 2617–2630. [Google Scholar] [CrossRef] [Scilit]
- Huang, Y.; Sun, Q.; Ren, Y.; Wang, R.; Chen, Z. Quantification of dynamic flexibility provided by district heating networks for electric power system. IEEE Trans. Reliab. 2025, 74, 2904–2915. [Google Scholar]
- Zhou, Y.; Hu, W.; Min, Y.; Dai, Y. Integrated power and heat dispatch considering available reserve of combined heat and power units. IEEE Trans. Sustain. Energy 2019, 10, 1300–1310. [Google Scholar]
- Zhang, T.; Wang, J.; Wang, H.; Ruiyang, J.; Li, G.; Zhou, M. On the coordination of transmission-distribution grids: A dynamic feasible region method. IEEE Trans. Power Syst. 2023, 38, 1857–1868. [Google Scholar]
- Dong, H.; Lu, P.; Jiang, X.; Chen, X.; Wang, P.; Zhu, J. Uncertainty feasible region analysis for microgrids in the coordination with distribution system considering interactive power deviation. Algorithms 2025, 18, 142. [Google Scholar] [CrossRef] [Scilit]
- Xiong, Z.; Zhang, C.; Qiu, D.; Wang, L.; Jiang, C.; Zhou, S. Feasible region identification approach for the regional integrated energy system considering flexible ramping constraints based on polyhedral projection algorithm. Int. J. Electr. Power Energy Syst. 2024, 163, 110347. [Google Scholar] [CrossRef] [Scilit]
- Gurobi Optimization, LLC. Gurobi Optimizer Reference Manual [EB/OL]. 2024. Available online: https://www.gurobi.com (accessed on 17 December 2025).
- Sahinidis, N.V. BARON: A general purpose global optimization software package. J. Glob. Optim. 1996, 8, 201–205. [Google Scholar] [CrossRef] [Scilit]
- Nagarajan, H.; Lu, M.; Yamangil, E.; Bent, R. Tightening McCormick relaxations for nonlinear programs via dynamic multivariate partitioning. In Proceedings of the 22nd International Conference on Principles and Practice of Constraint Programming (CP 2016), Toulouse, France, 5–9 September 2016; Lecture Notes in Computer Science. Volume 9892, pp. 369–387. [Google Scholar]
- Castro, P.M. Normalized multiparametric disaggregation: An efficient relaxation for mixed-integer bilinear problems. J. Glob. Optim. 2016, 64, 765–784. [Google Scholar]
- Kolodziej, S.; Castro, P.M.; Grossmann, I.E. Global optimization of bilinear programs with a multiparametric disaggregation technique. J. Glob. Optim. 2013, 57, 1039–1063. [Google Scholar] [CrossRef] [Scilit]
- Andrade, T.; Oliveira, F.; Hamacher, S.; Eberhard, A. Enhancing the normalized multiparametric disaggregation technique for mixed-integer quadratic programming. J. Glob. Optim. 2019, 73, 701–722. [Google Scholar]
- Barbulescu, C.; Kilyeni, S.; Vuc, G.; Lustrea, B.; Precup, R.-E.; Preid, S. Software tool for power transfer distribution factors (PTDF) computing within the power systems. In Proceedings of the IEEE Region 8 EUROCON 2009 Conference, Saint Petersburg, Russia, 18–23 May 2009; pp. 532–539. [Google Scholar]
- McCormick, G.P. Computability of global solutions to factorable nonconvex programs: Part I—Convex underestimating problems. Math. Program. 1976, 10, 147–175. [Google Scholar] [CrossRef] [Scilit]
- Glover, F. Improved linear integer programming formulations of nonlinear integer problems. Manag. Sci. 1975, 22, 455–460. [Google Scholar] [CrossRef] [Scilit]
- IPHS_6bus_6node. Available online: https://docs.google.com/spreadsheets/d/16sBNE8U97_2zNCUTE5uWUE8CahYxMFzL/edit?usp=drive_link&ouid=101356593947876887798&rtpof=true&sd=true (accessed on 17 December 2025).
- Liu, X. Combined Analysis of Electricity and Heat Networks; Cardiff University: Cardiff, UK, 2013. [Google Scholar]
- Dai, Y. Modelling and Analysis of the Integrated Electrical-Thermal System Considering Heat Transfer and Transport Processes; Tsinghua University: Beijing, China, 2018. [Google Scholar]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.