


Abstract
The control synchronization of multiple electrohydraulic actuators (MEHAs) is initially discussed to ensure the consensus of every electrohydraulic actuator (EHA) with three-order isomorphic dynamics. First, the EHA model is linearized using the Lie derivative method to obtain the state-space model of MEHAs. Then, the disturbance observer is used to estimate and compensate for the unknown external load caused by the driving force of a motion plant. Via the Lyapunov technique, this protocol asymptotically achieves consensus to a zero neighborhood with the ultimate boundaries of the MEHAs’ state errors. The effectiveness of the synchronous control protocol is verified by both simulation and experimental benches with two-node EHAs.
1. Introduction
An electrohydraulic servo system (EHSS) represents a popular driving actuator used in some areas of mechanical engineering such as hydraulic exoskeletons [1], hydraulic bouncing systems [2], quadruped robotics [3], hydraulic manipulators [4], shaking tables [5], etc. Previous works on EHSS and other mechatronics focused on uncertain parametric estimations [6,7,8,9,10] and external load compensations [11,12,13,14,15,16]. By not addressing the uncertainty and external load, the EHSS output performance will decline. In addition, some uncertainties and disturbances are well handled in pneumatic loading systems [17] and electric power systems [18] by using adaptive control and data-mining technologies. Furthermore, some parallel mechanisms driven by multiple electrohydraulic actuators, such as shaking tables [19] and spatial electrohydraulic robots [20], are more challenging for realizing collaborative control since the coupling nonlinearity should be addressed in advance.
The problem of the synchronous control of multiple EHSSs was initiated by Jafari et al. [21]. The author proposed a distributed average consensus protocol used in the velocity control loop of four EHSS nodes. This is the first time that multiagent control theory and network topology has been integrated into an EHSS plant. Actually, distributed multiagent cooperation [22] has recently garnered a lot of attention in the information domain, such as formation spacecraft flight [23], distributed sensor networks [24], and collaborative surveillance [25]. Nowadays, the distributed consensus is a fundamental problem for multiagent collaborative control, which is closely related to formation control [26] and flocking problems [27]. The consensus protocol is designed to guarantee that many agents achieve an agreement on finite quality. In the past twenty years, many researchers have studied multiagent consensus problems from different perspectives and written several papers. For example, a theoretical framework for the consensus algorithms [28] was designed in multiagent network systems based on modern control techniques, matrix theory, and algebraic graphs. Meanwhile, the cooperative control of autonomous mobile agents [29] was studied with multiple leaders using different interconnection methods. To address the consensus of multiagent systems with general linear and Lipschitz nonlinear dynamics, Li et al. [30,31] presented both distributed adaptive static and dynamic consensus controllers. Subsequently, an adaptive robust NN control for every node was given in [32] to address the tracking consensus for nonlinear systems with high-order dynamics. In addition, the consensus problem of directed multiagent networks [33] was discussed with a variable delay and intrinsic nonlinear dynamics. The finite-time consensus issue of multiagent systems was considered in [34]. The necessary and sufficient conditions for common linear and a two-order multiagent consensus [35,36] were derived to solve the linear multiagent consensus problem. Many distributed consensus algorithms [37,38,39] were often handled by linear matrix inequality to achieve consensus. Considering switch control theory, Wen et al. [40] provided proof that a multiagent system’s consistency with a spanning tree could be converted into the stability proof of many low-dimensional systems. Meanwhile, the consensus algorithm was also proposed in the smallest real part of the Laplacian matrix with non-zero eigenvalues [41,42,43], which adopted both its own and its neighbors’ local data. To avoid known global data of the Laplacian matrix, adaptive consensus protocols were presented by Li et al. [44] and Su et al. [45], which depended on the neighbors’ relative states. Unlike [46], this work considers an average consensus rather than a lead-following tracking synchronization based on an undirected graph for network topology.
Thanks to the above references for multiagent distributed control, this study has the following contributions:
(i) A basic synchronous controller is tested in multiple EHAs to realize the consensus of every EHA node with three-order nonlinear dynamics and an unknown external load. To the best of the authors’ knowledge, this synchronous controller based on graph theory has not been applied to an electrohydraulic plant until now.
(ii) By using the feedback linearization method, the linear model of MEHAs is set up to conveniently design the synchronous consensus algorithm. Furthermore, a state-feedback matrix is derived from the pole placement technique, which is considered in the synchronous controller and improves the stable margin of MEHAs. Meanwhile, the general disturbance observer is adopted to estimate the external load.
(iii) Unlike many of the previous references, a two-DOF robotic bench driven by electrohydraulic actuators is used as the experimental bench for MEHAs with two nodes, which can verify the proposed synchronous consensus protocol.
This manuscript has the following organization. The multiple electrohydraulic motion model is constructed in Section 2. The synchronous control protocol is given in Section 3. The simulations and the experimental verification of MEHAs are given in Section 4 and Section 5. Finally, the conclusion is drawn in Section 6.
2. Motion Plant Description
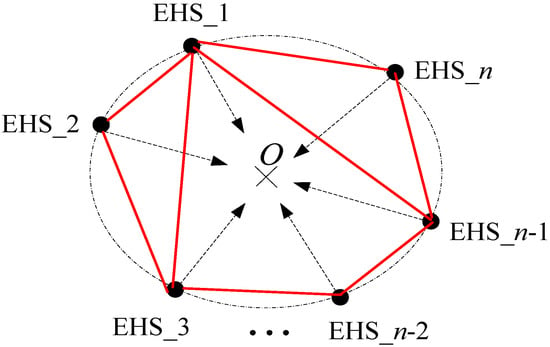
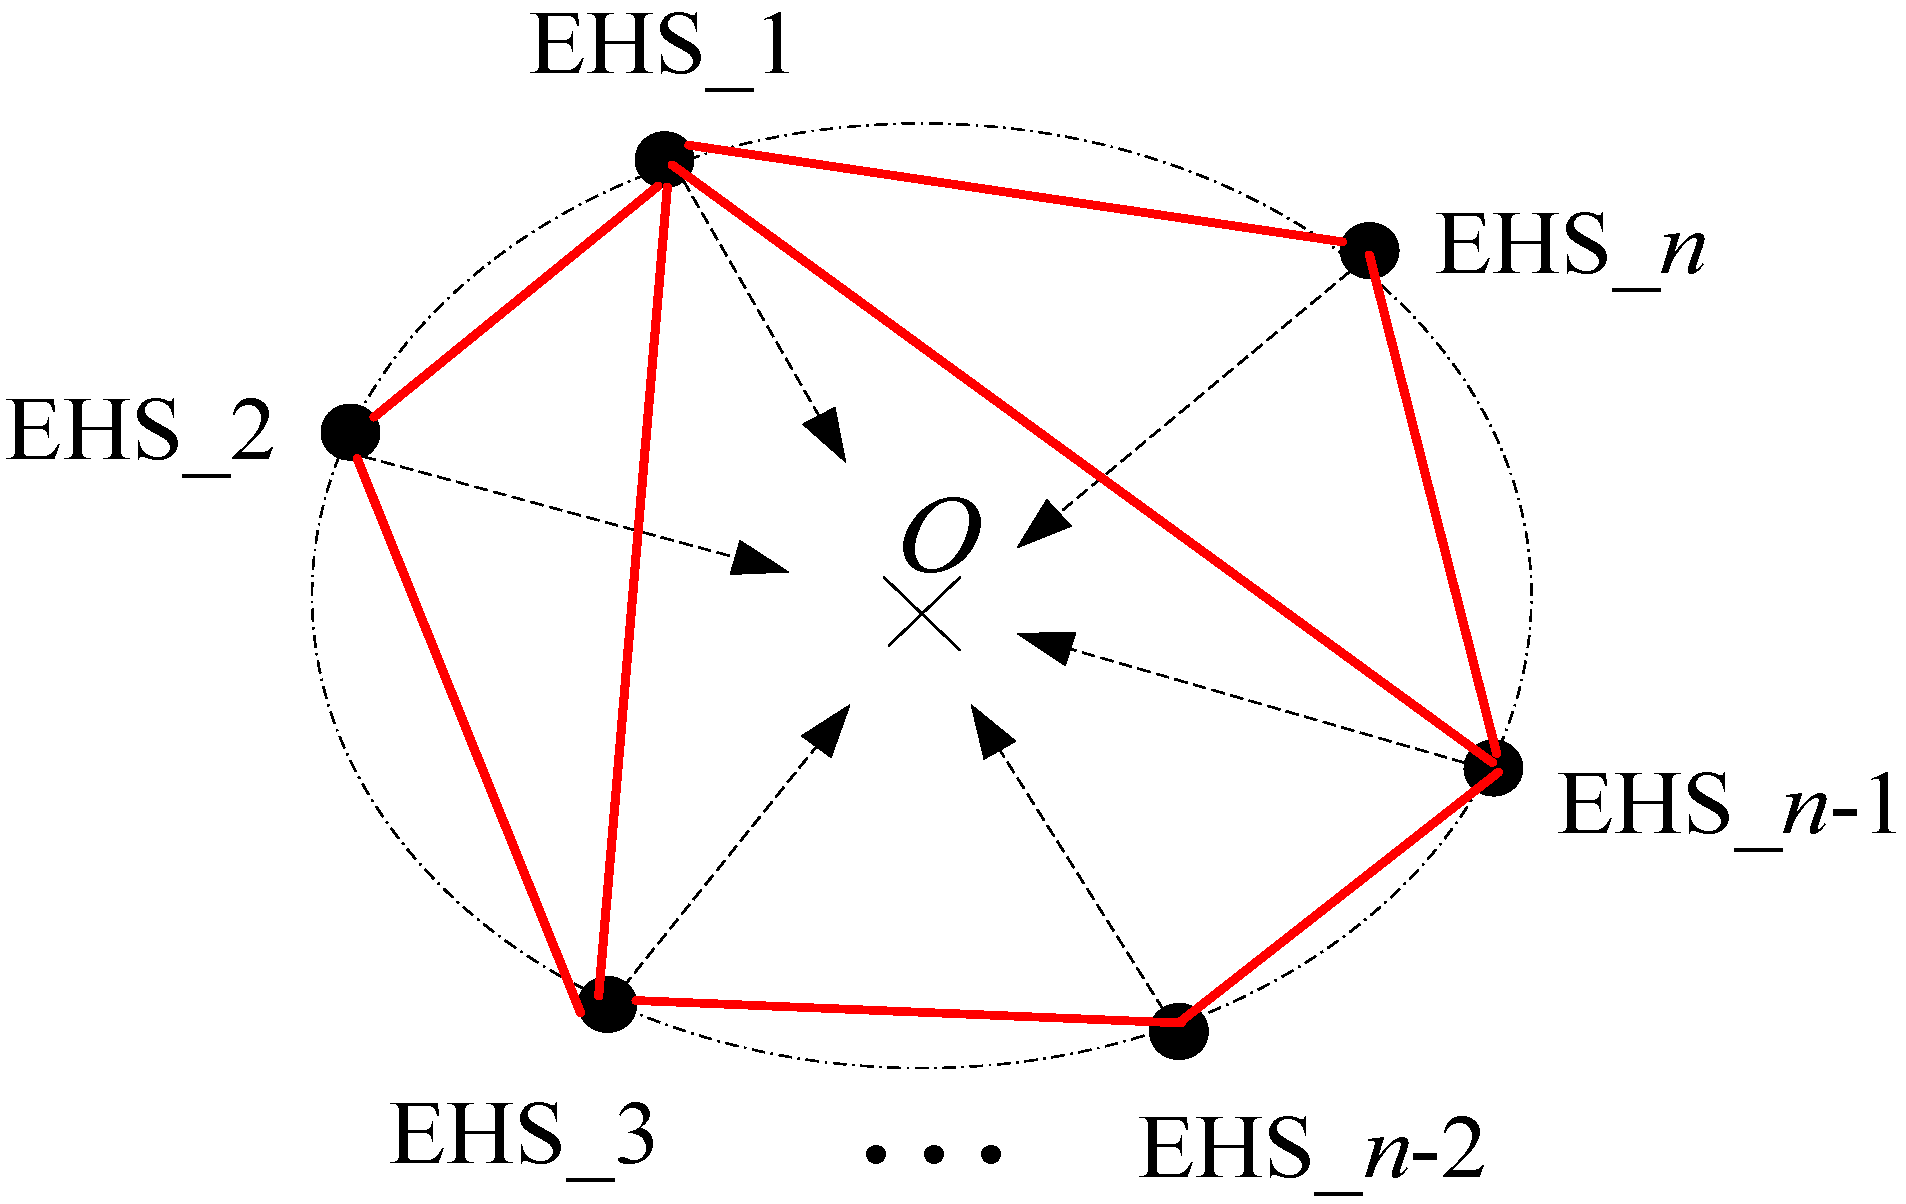
A synchronous control scheme for MEHAs’ average consensus in a network topology based on undirected graph theory is described in Figure 1. Every electrohydraulic node has an isomorphic model and standalone control protocol. A MEHAs cooperation guarantees every EHA’s consensus to their center balance state O using the synchronous control protocol design of the corresponding EHA.
Figure 1.
The synchronous control scheme for MEHAs’ average consensus in a network topology based on undirected graph theory.
2.1. Nonlinear Dynamics of MEHAs
Jn Reference [47], the EHA had three system states such that . Hence, the linear state space model for the EHA is described as
where is a signum function.
If the hydraulic parameters are assumed to be constant and a priori in every EHA model, then the model in (1) is rewritten as
where
Remark 1.
The function is bounded and positive because the state yields .
Assumption 1
([11]). The external load is a variable disturbance that relies on the mechanical plant motion, i.e., . However, is bounded such that , where is an unknown constant.
2.2. Feedback Linearization Transformation
Consider the single-input and single-output systems for the EHA (2). Via the Lie derivative method [48], the precise feedback linearization model of MEHAs is derived using the following procedure.
At first, a new state vector is described such that . Because the derivative includes the control , the nonlinear model (2) has three relative orders. Therefore, , , and yield
Secondly, the dynamic is linearized using the Lie derivative technique as follows:
In a linearized model, in (2) is converted into the new control variable , which has the following condition
where
Hence, the feedback linearization model for (2) is derived as follows:
where
.
In (5)–(7), the feedback linearization model of the MEHAs’ nonlinear dynamics is described as
and is standardized to the state space form
Remark 2.
The model in (9) is a precise linearization of the primary model in (1). Moreover, the control in (5) and its transformed form in (9) are inverse.
3. Synchronous Protocol Derivation
For a compact denotation, the state vector of MEHAs and the corresponding synchronous protocol are defined. Then the state space model of MEHAs is given by
where .
Definition 1
([49]). A graph is a pair , where is a finite nonempty node set and is an edge set of ordered pairs of nodes. The edge in the edge set of a directed graph denotes that vehicle j can obtain the information from vehicle i, i.e., . If , then the called weight of an edge , else . An undirected graph is a special case of a directed graph, where an edge in the undirected graph corresponds to edges and in the directed graph. Then, a Laplacian matrix of MEHAs is defined as as follows:
Since the external load is unknown in (10), the disturbance observer is designed as follows:
where denotes a diagonal gain, is a state feedback gain of the disturbance observer, e is the transformation of the state vector defined as , and P is a positive definite matrix to be selected.
The synchronous control protocol of the MEHAs is given by
where , the constant , is the minimal eigenvalue of , , is a state-feedback matrix using pole placement, and .
Remark 3.
The MEHAs’ consensus is directly guaranteed by the first item of in (13). The second item is the pole configuration, which improves the system-stable margin of each EHA. The external disturbance is compensated for by the last item .
Remark 4.
The state-feedback matrix is used to transform the system matrix into a stable system matrix using pole placement as . In other words, the new system matrix’s eigenvalues .
Theorem 1.
The MEHAs system in (10) involves the synchronous control protocol in (13) and the disturbance observer in (12) under Assumption 1. If there exists a positive definite matrix P, it yields
where , δ and k are positive constants, then every node state , where Δ is bounded and α is a positive constant, i.e., the protocol in (13) asymptotically achieves consensus to a zero neighborhood with an arbitrarily small size.
Proof.
For the state vector of the MEHAs in (10), the candidate Lyapunov function is chosen as follows:
where the first evaluation item is the consensus errors of the MEHAs and the other item is the observer estimation errors.
Then, the derivative yields
Substituting the synchronous control protocol in (13) into (17), yields
where
Let , and substituting the disturbance observer in (12) into (17), is given by
In (19), the item involves the unknown variable matrix P and the specified matrix . If is designed as , then the first item in (19) is converted into an LMI as follows:
For the Laplacian matrix of MEHAs, there exists an orthogonal matrix U such that , where is a diagonal matrix. Then, a linear transformation is defined as , and is rewritten as
where is the minimal eigenvalue of , except for the only zero eigenvalue.
Since the constant c is designed as in (13), according to the LMI condition (14), yields
Let ; satisfies
Integrate the two sides of (23) and V yields
Now, from (24), let , the convergence domain for the MEHAs’ synchronous error is . Furthermore, the dimension of mainly relies on the magnitude . Thus, the larger constant k and the smaller constant can reduce the dimension of when . □
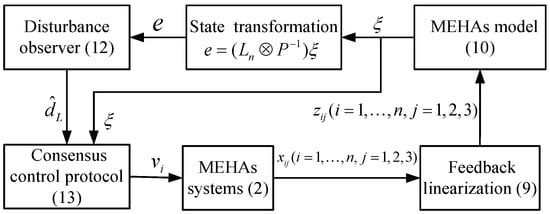
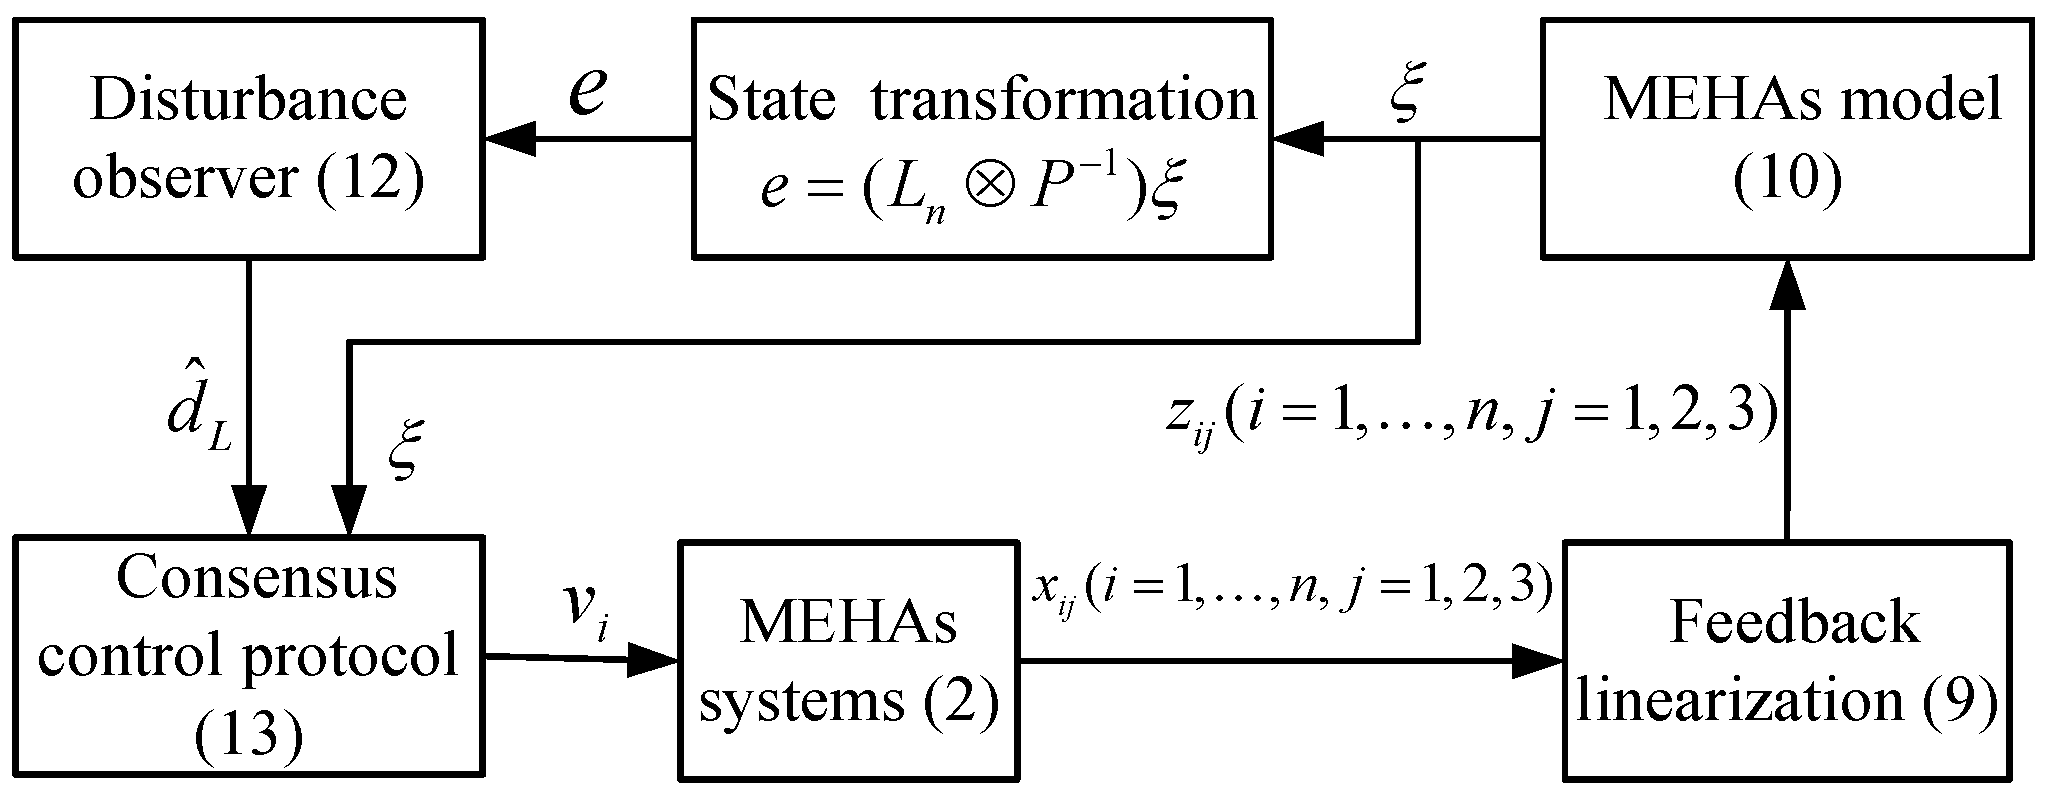
Figure 2 shows the flow chart of the average consensus control scheme of the MEHAs. The MEHAs’ nonlinear dynamics are set up (2). Using the feedback linearization method, the MEHAs’ linear form is represented (9), from which the state space model of the MEHAs is derived (10). To address the unknown external load, the disturbance observer (12) is designed and compensated for in the synchronous control protocol (13). This synchronous protocol is based on the undirected graph shown in Figure 1, which means that each node can share its respective information. The objective of the proposed synchronous protocol is to guarantee the state consensus of all nodes.
Figure 2.
The flow chart of the average consensus control scheme.
4. Simulation Results
For the convenience and consistency of the following experiments, two EHAs are simulated to verify the proposed synchronous control scheme. Some model parameters of MEHAs are given by , , , , , , = 40 bar, = 2 bar, and = 4.91 . The two external load disturbances are assumed to be and . The disturbance observer parameters are and . The synchronous control parameters are , , , , and . The state-feedback matrix is and its corresponding pole placement is for the matrix . The initial values of the two EHAs are mm, mm/s, N, mm, mm/s, and N.
4.1. Simulation Verification of the Two Nodes
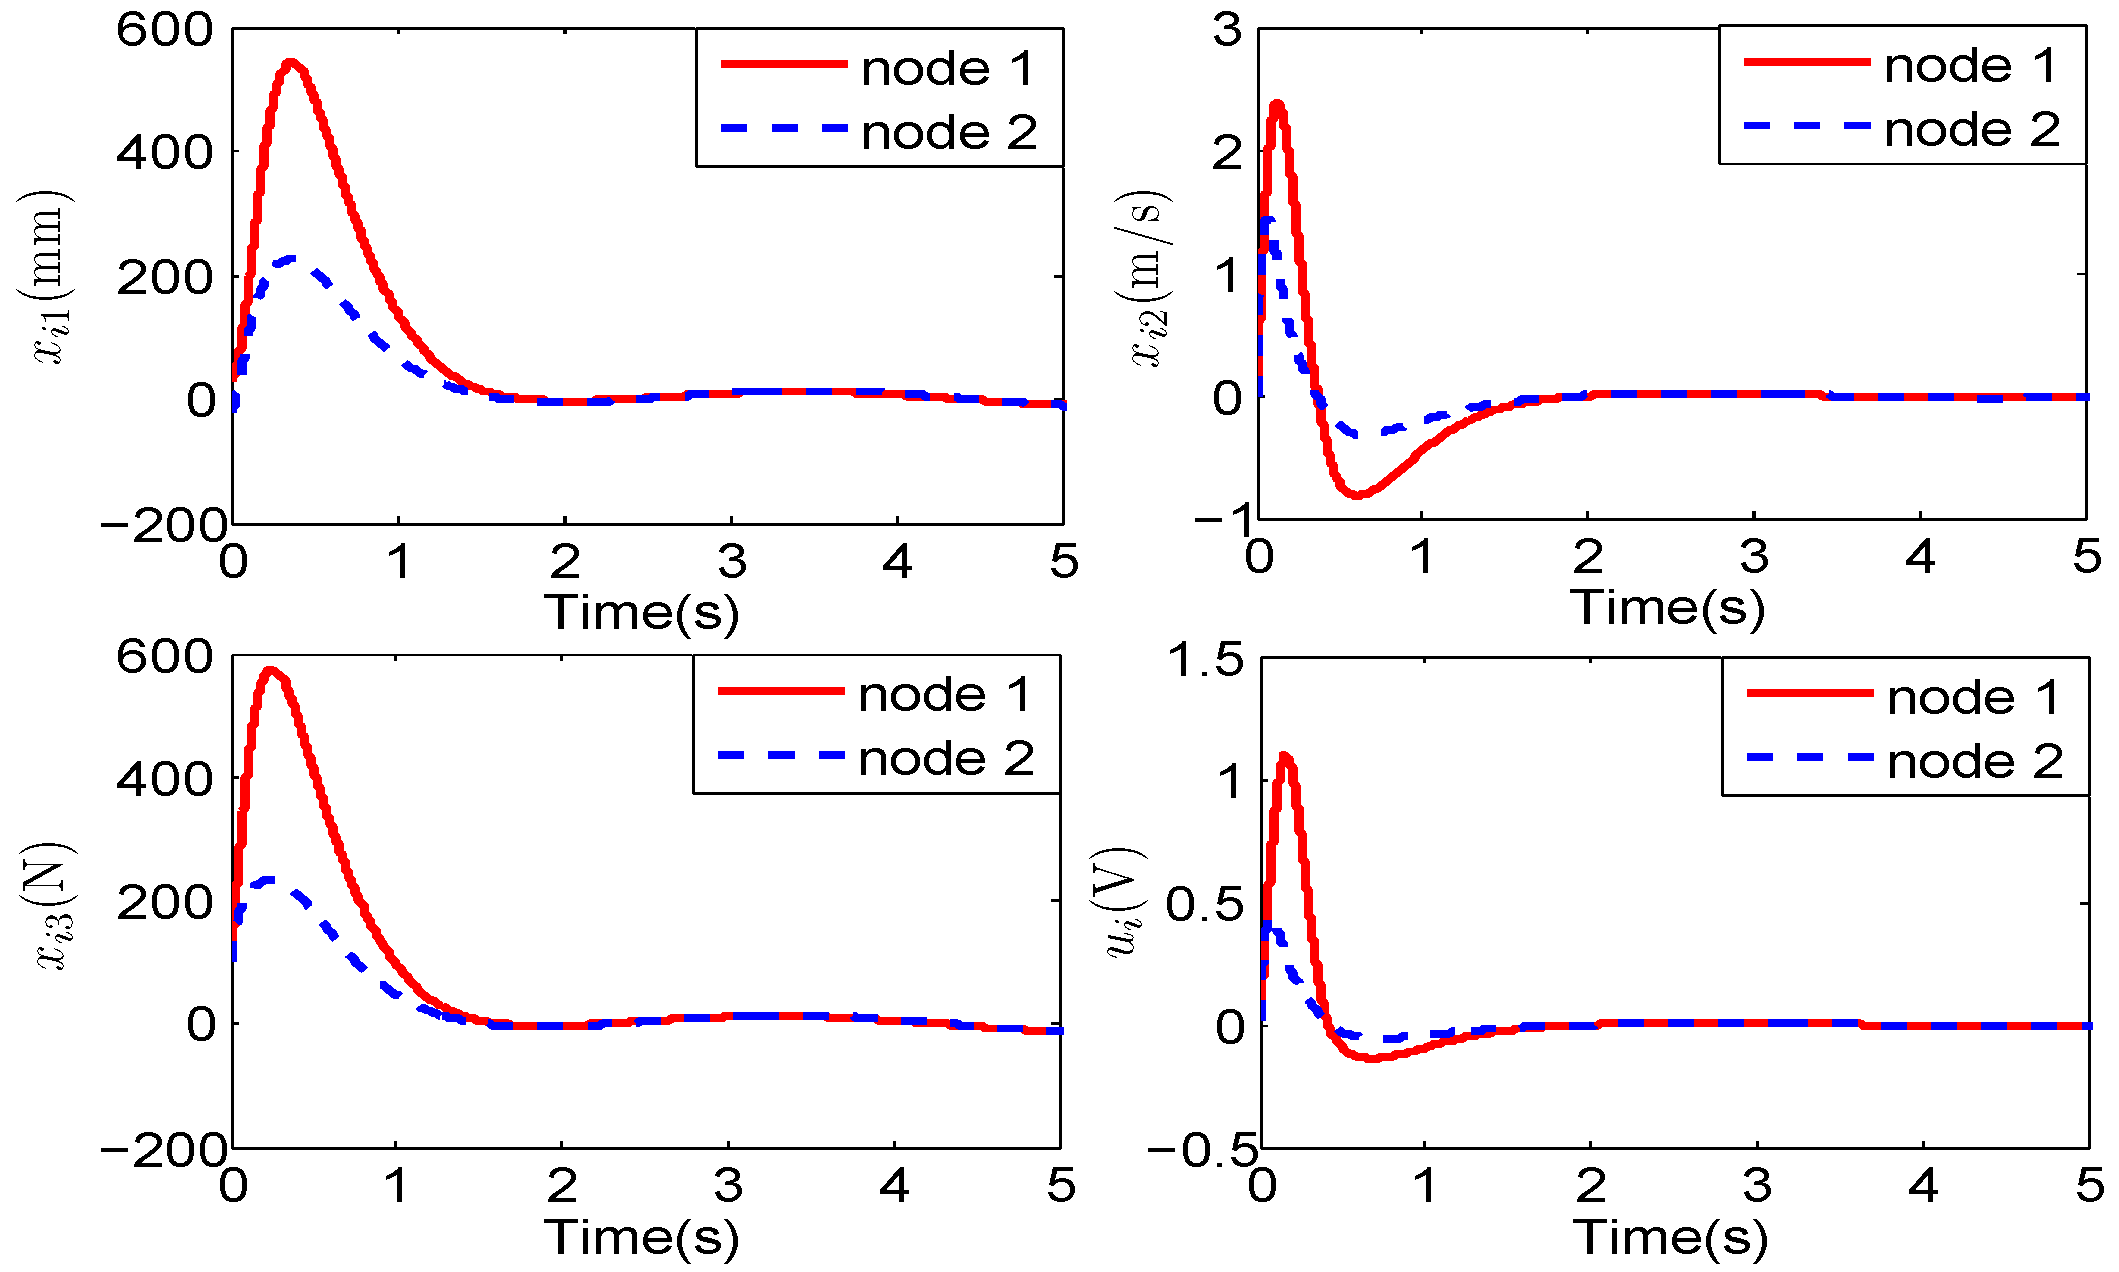
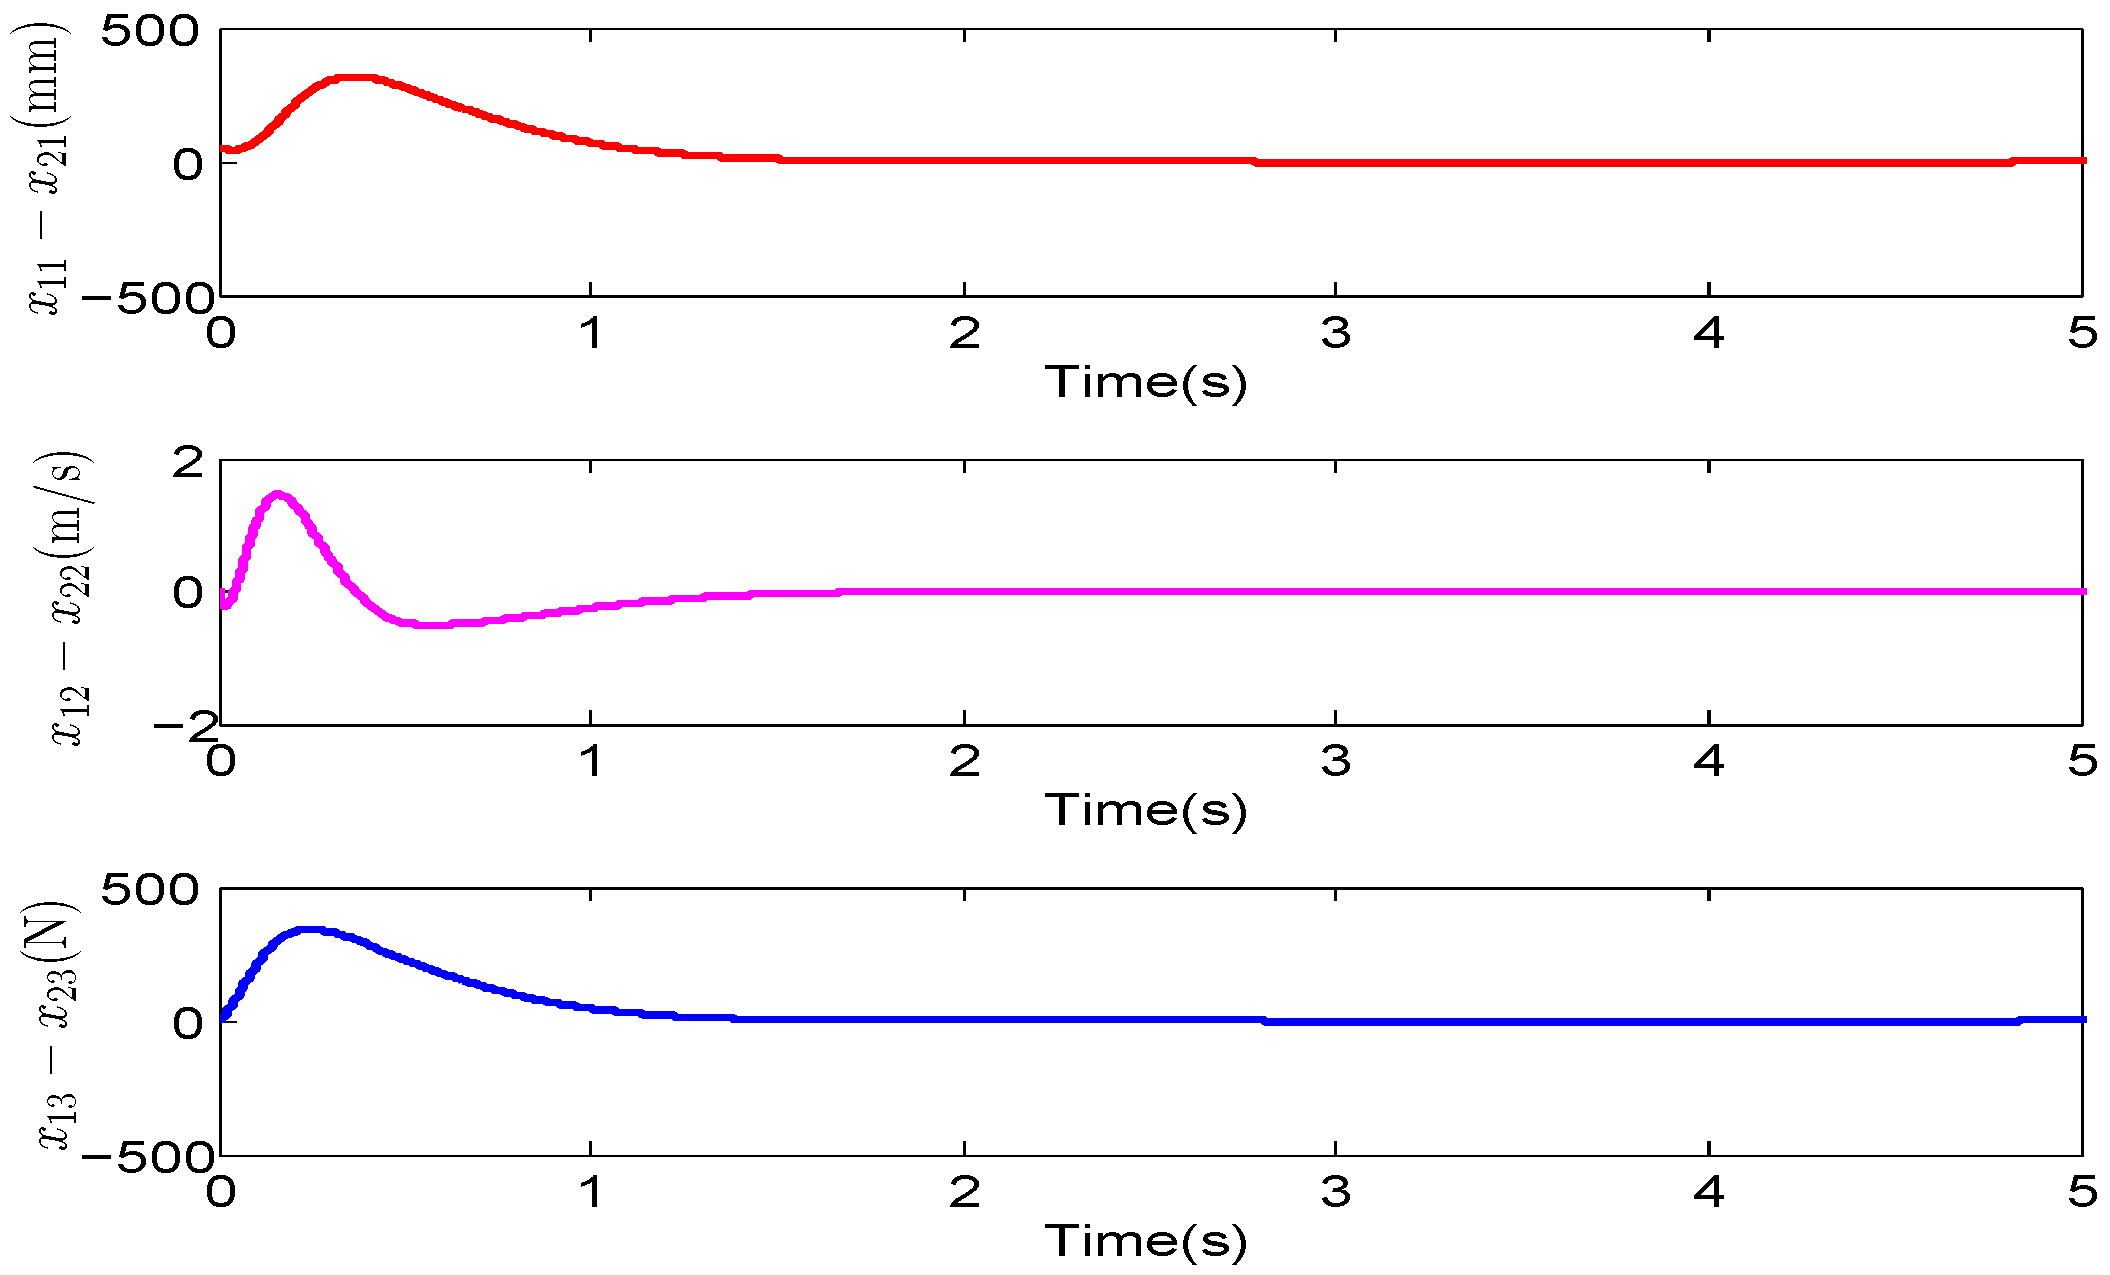
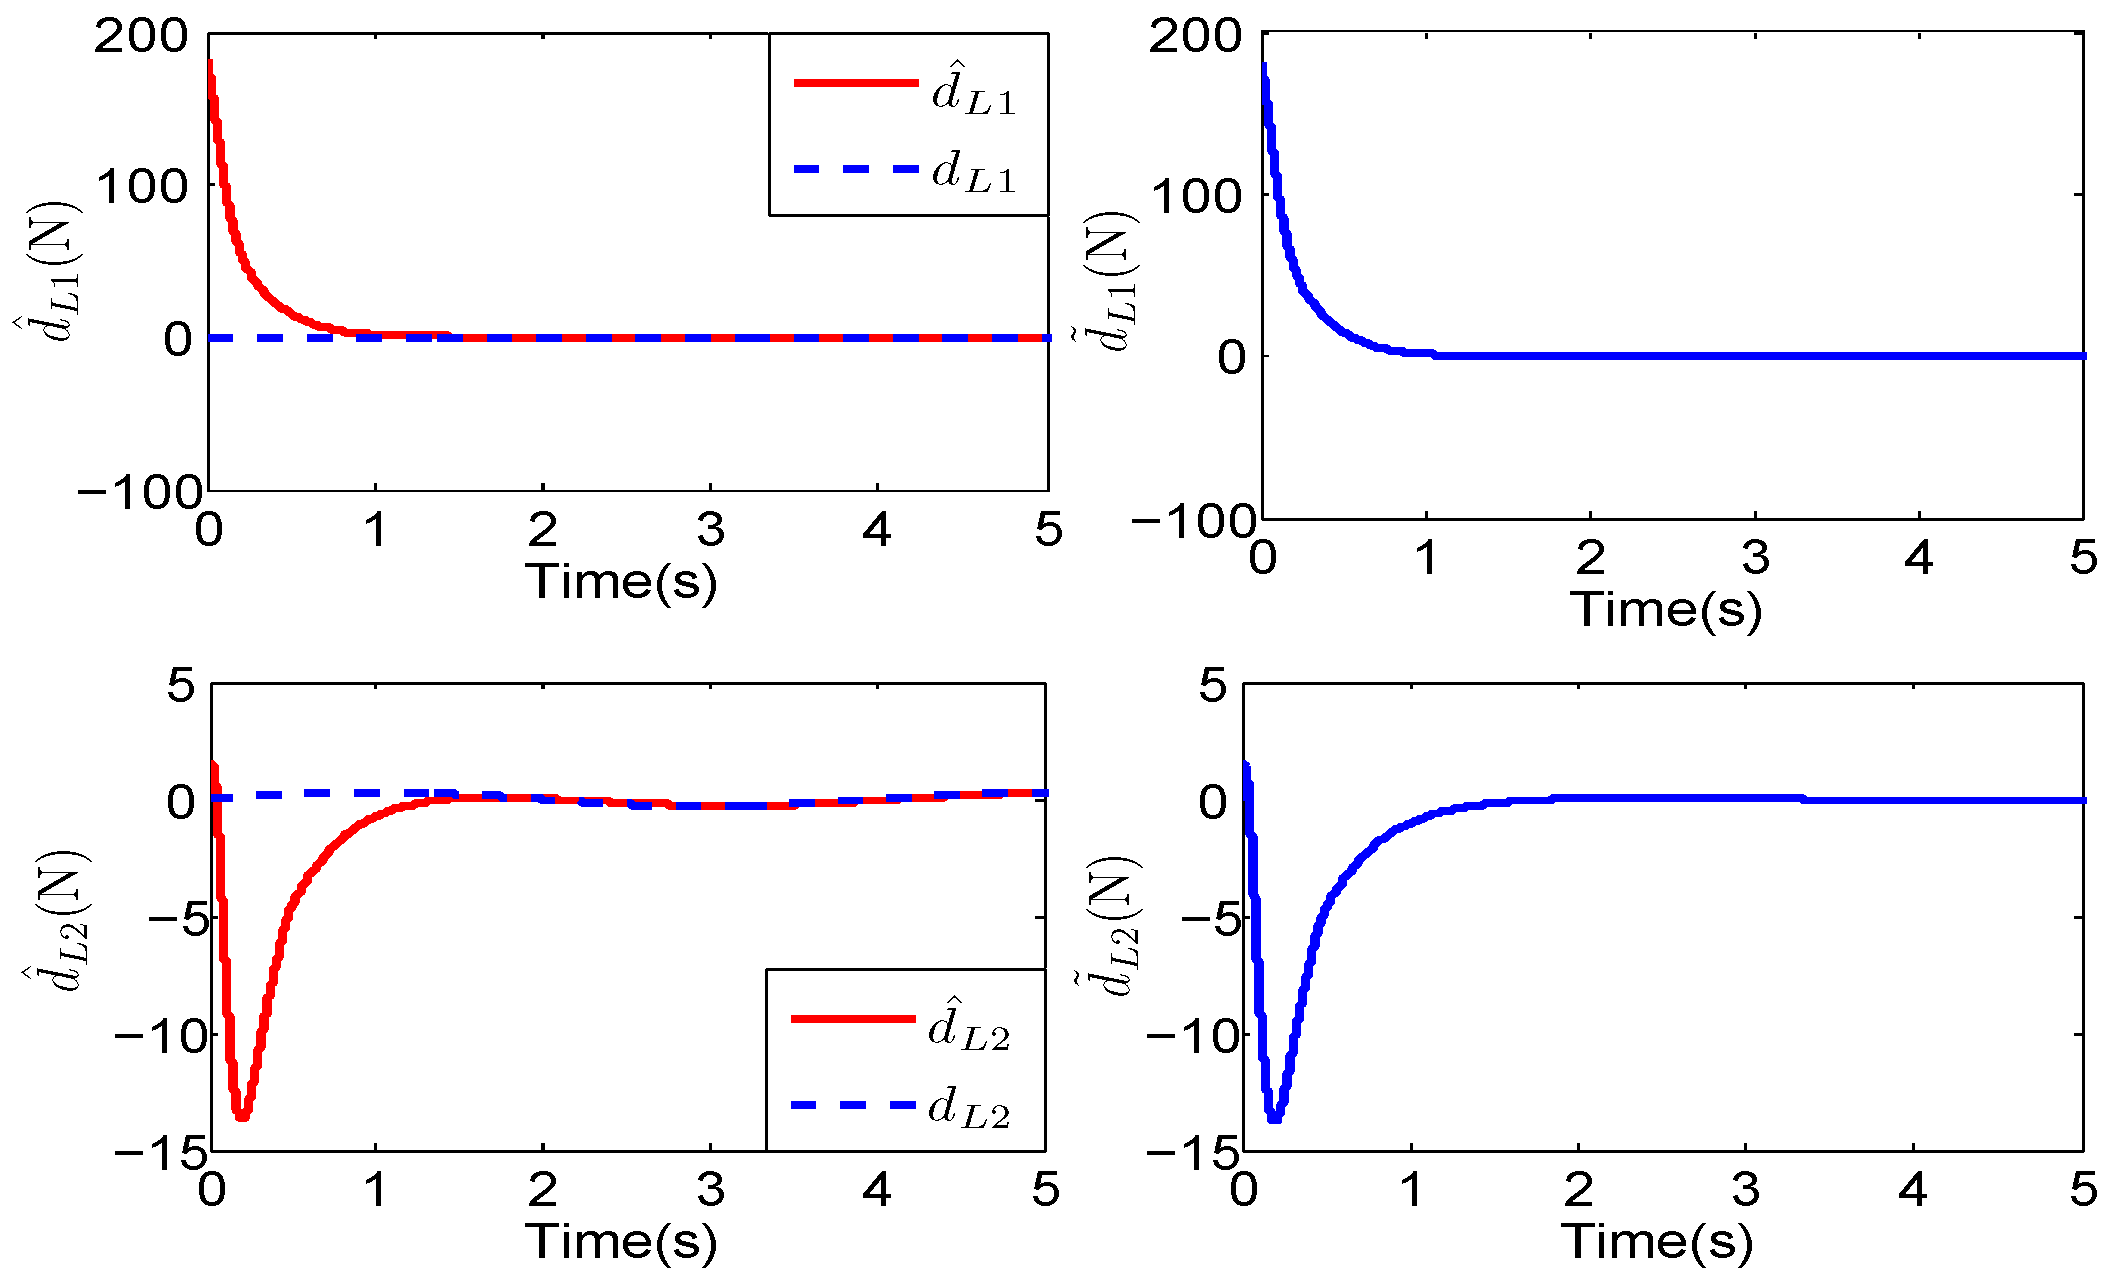
The simulation results of the average consensus controller are shown in Figure 3, Figure 4 and Figure 5. Since MEHAs have an undirected topology, as shown in Figure 1, the corresponding state responses of the two nodes achieved consensus, as shown in Figure 3. In other words, the synchronous state errors involving the cylinder position error , the velocity error , and the load pressure error converged to zero using the synchronous control protocol (13), as shown in Figure 4. In addition, by using the disturbance observer (12), the disturbance estimation is well regulated to track the real disturbance value with a satisfactory disturbance estimation error , as shown in Figure 5.
Figure 3.
The MEHAs’ state responses of the two nodes in the simulation: —the cylinder position; —the cylinder velocity; —the cylinder load pressure; —the control voltage of the servo valve.
Figure 4.
The MEHAs’ state errors of the two nodes in the simulation: (the red line) —the cylinder position error; (the pink line) —the cylinder velocity error; (the blue line) —the cylinder load pressure error.
Figure 5.
The disturbance observers and their corresponding errors of the two nodes in the simulation: is the disturbance actual value, is the disturbance observer estimation, is the disturbance estimation error.
4.2. Comparison with Different State-Feedback Matrices
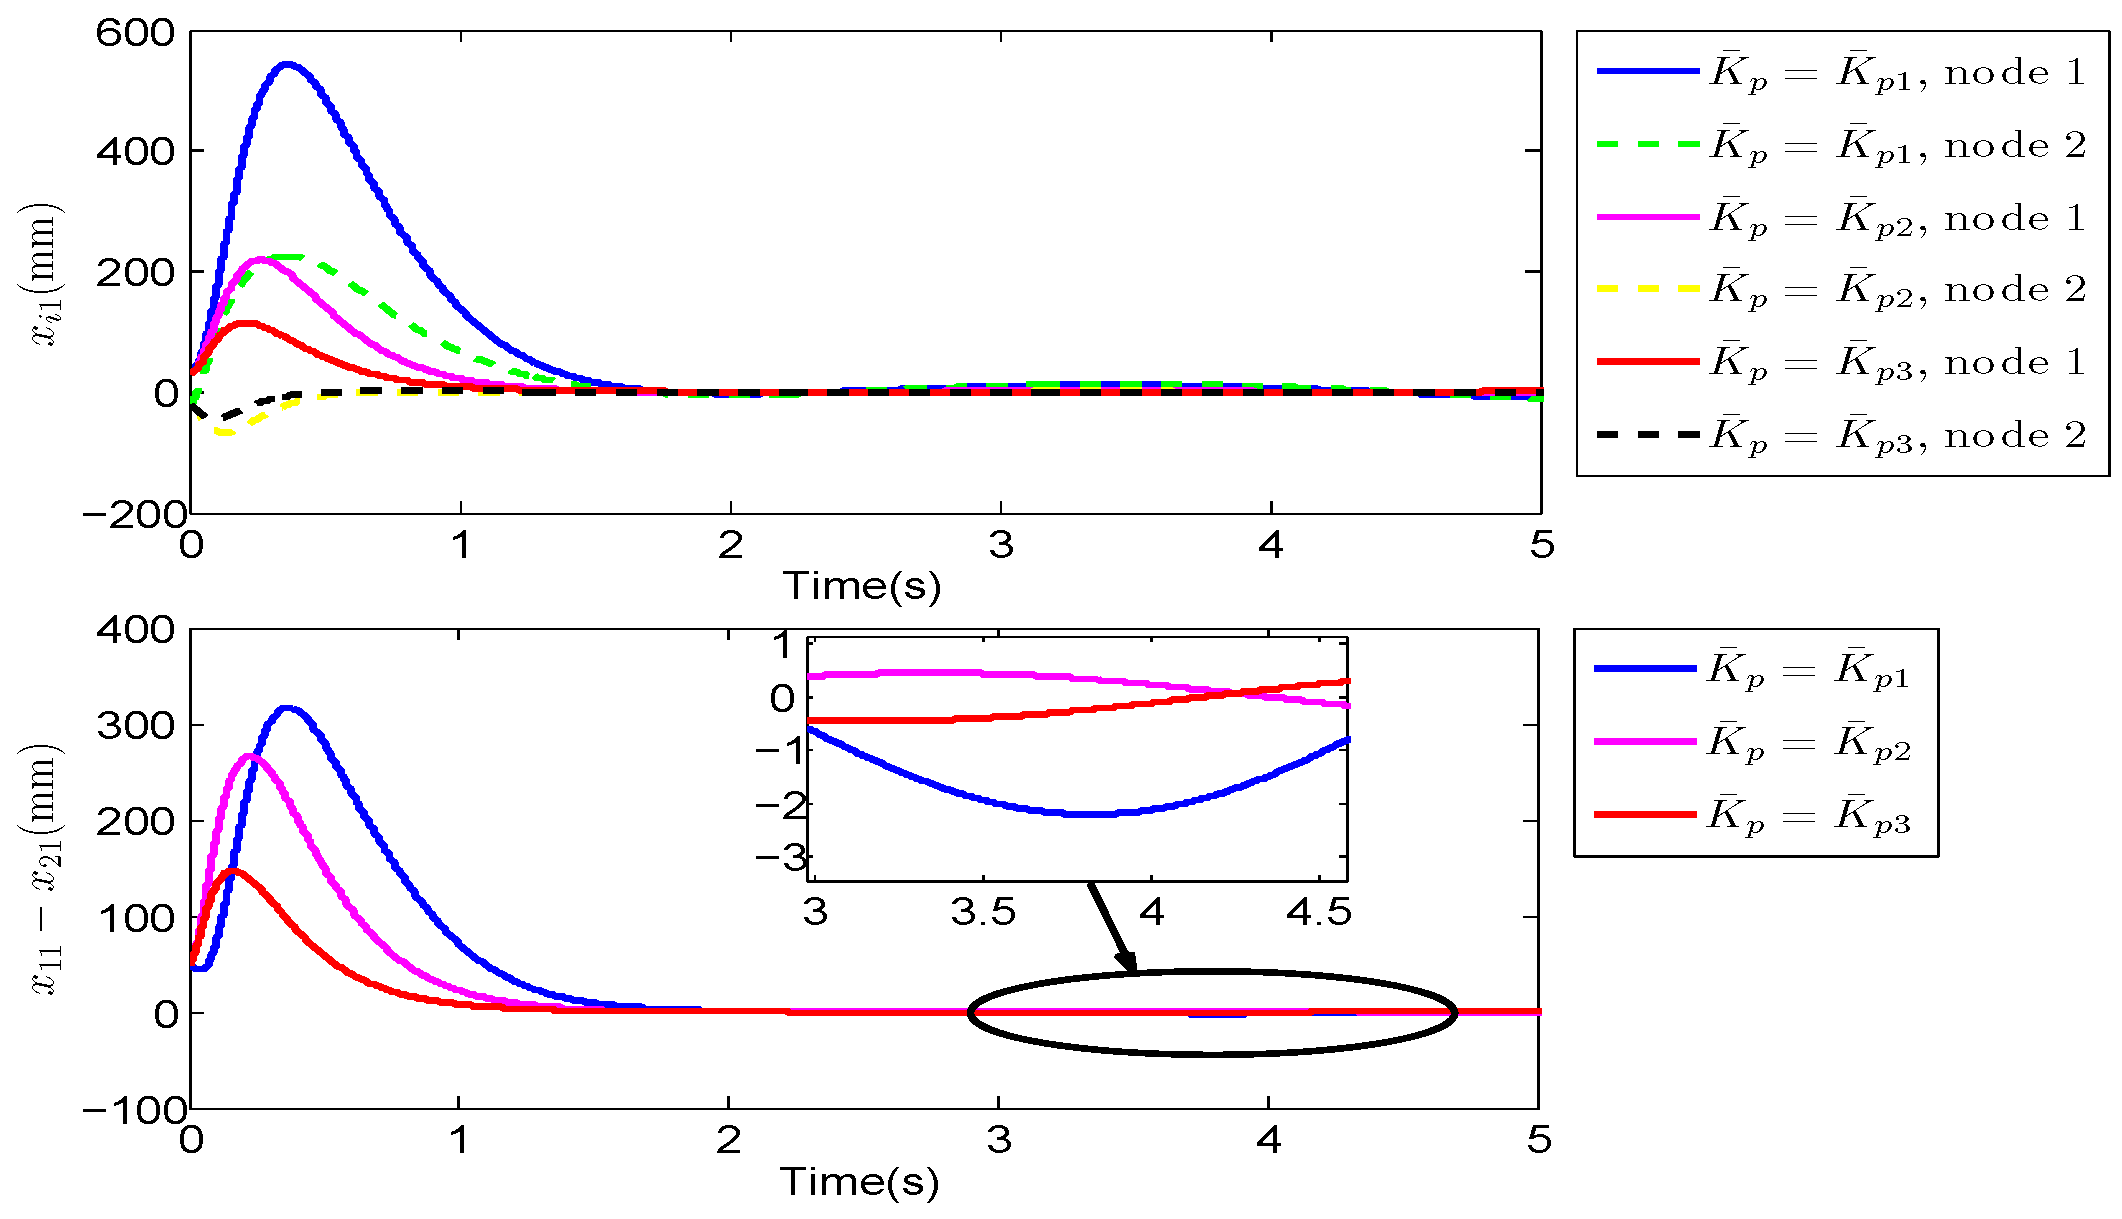
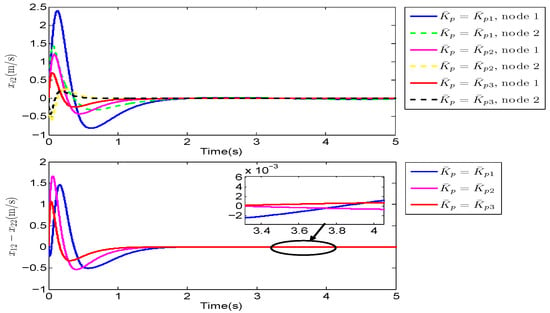
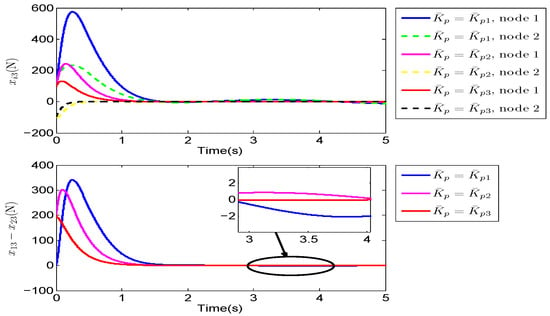
To analyze the consensus rate of the two nodes, the other two state-feedback matrices mentioned in the synchronous control protocol (13) are selected as and . The respective pole placements are and . The corresponding comparative state response results are shown in Figure 6, Figure 7 and Figure 8. The consensus rate with the state-feedback matrix was faster than that of the other two conditions since its matrix had the largest gain elements among the three conditions. In other words, the larger the state-feedback gain , the faster the consensus rate. Furthermore, the three steady-state errors with respect to the largest matrix gain were less than those of the other two conditions, which indicates the favorable consensus effect using the proposed synchronous control protocol.
Figure 6.
The comparative position response results of the three state-feedback matrixes using pole placement in the simulation.
Figure 7.
The comparative velocity response results of the three state-feedback matrices using pole placement in the simulation.
Figure 8.
The comparative pressure response results of the three state-feedback matrices using pole placement in the simulation.
5. Experimental Verification
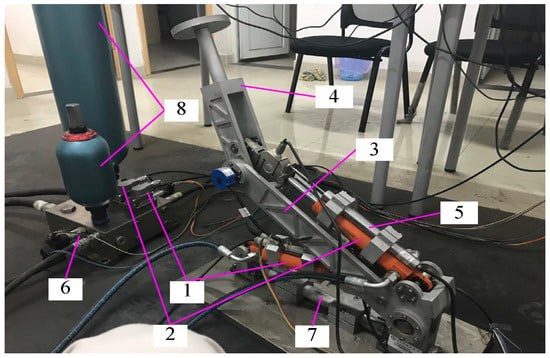
To verify the synchronous control scheme for MEHAs, the experimental bench with two electrohydraulic actuator nodes is built, which is shown in Figure 9. Each EHA node is composed of a servo valve and a hydraulic cylinder, respectively, which drive the robotic upper arm and forearm motion simultaneously. In fact, the dynamics of the two robotic arms become the two external loads of the MEHAs. The MEHAs’ three states are measured by the displacement and pressure transducers, respectively. The measured resolutions for the displacement and pressure transducers are less than . The range of the hydraulic cylinder is 80 mm due to the joint constraints of the robotic arm. An accumulator is adopted to supply the hydraulic transient flow. The disturbance observer parameters are and . The synchronous control parameters are , , , , , and . The initial values of the two EHAs are mm, mm/s, N, mm, and mm/s, N.
Figure 9.
The experimental bench construction of the MEHAs with two EHA nodes: 1—node 1 (servo valve 1 and hydraulic cylinder 1); 2—node 2 (servo valve 2 and hydraulic cylinder 2); 3—robotic upper arm; 4—robotic forearm; 5—displacement transducer; 6—pressure transducer; 7—bench torso; 8—accumulator.
5.1. Experimental Verification of Two Nodes
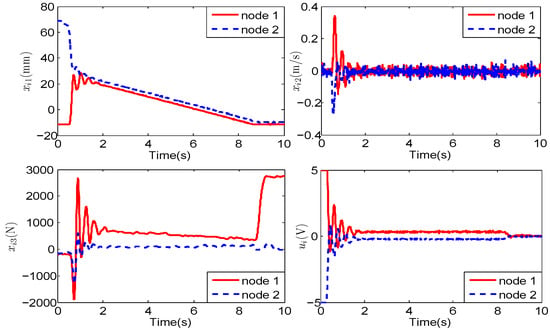
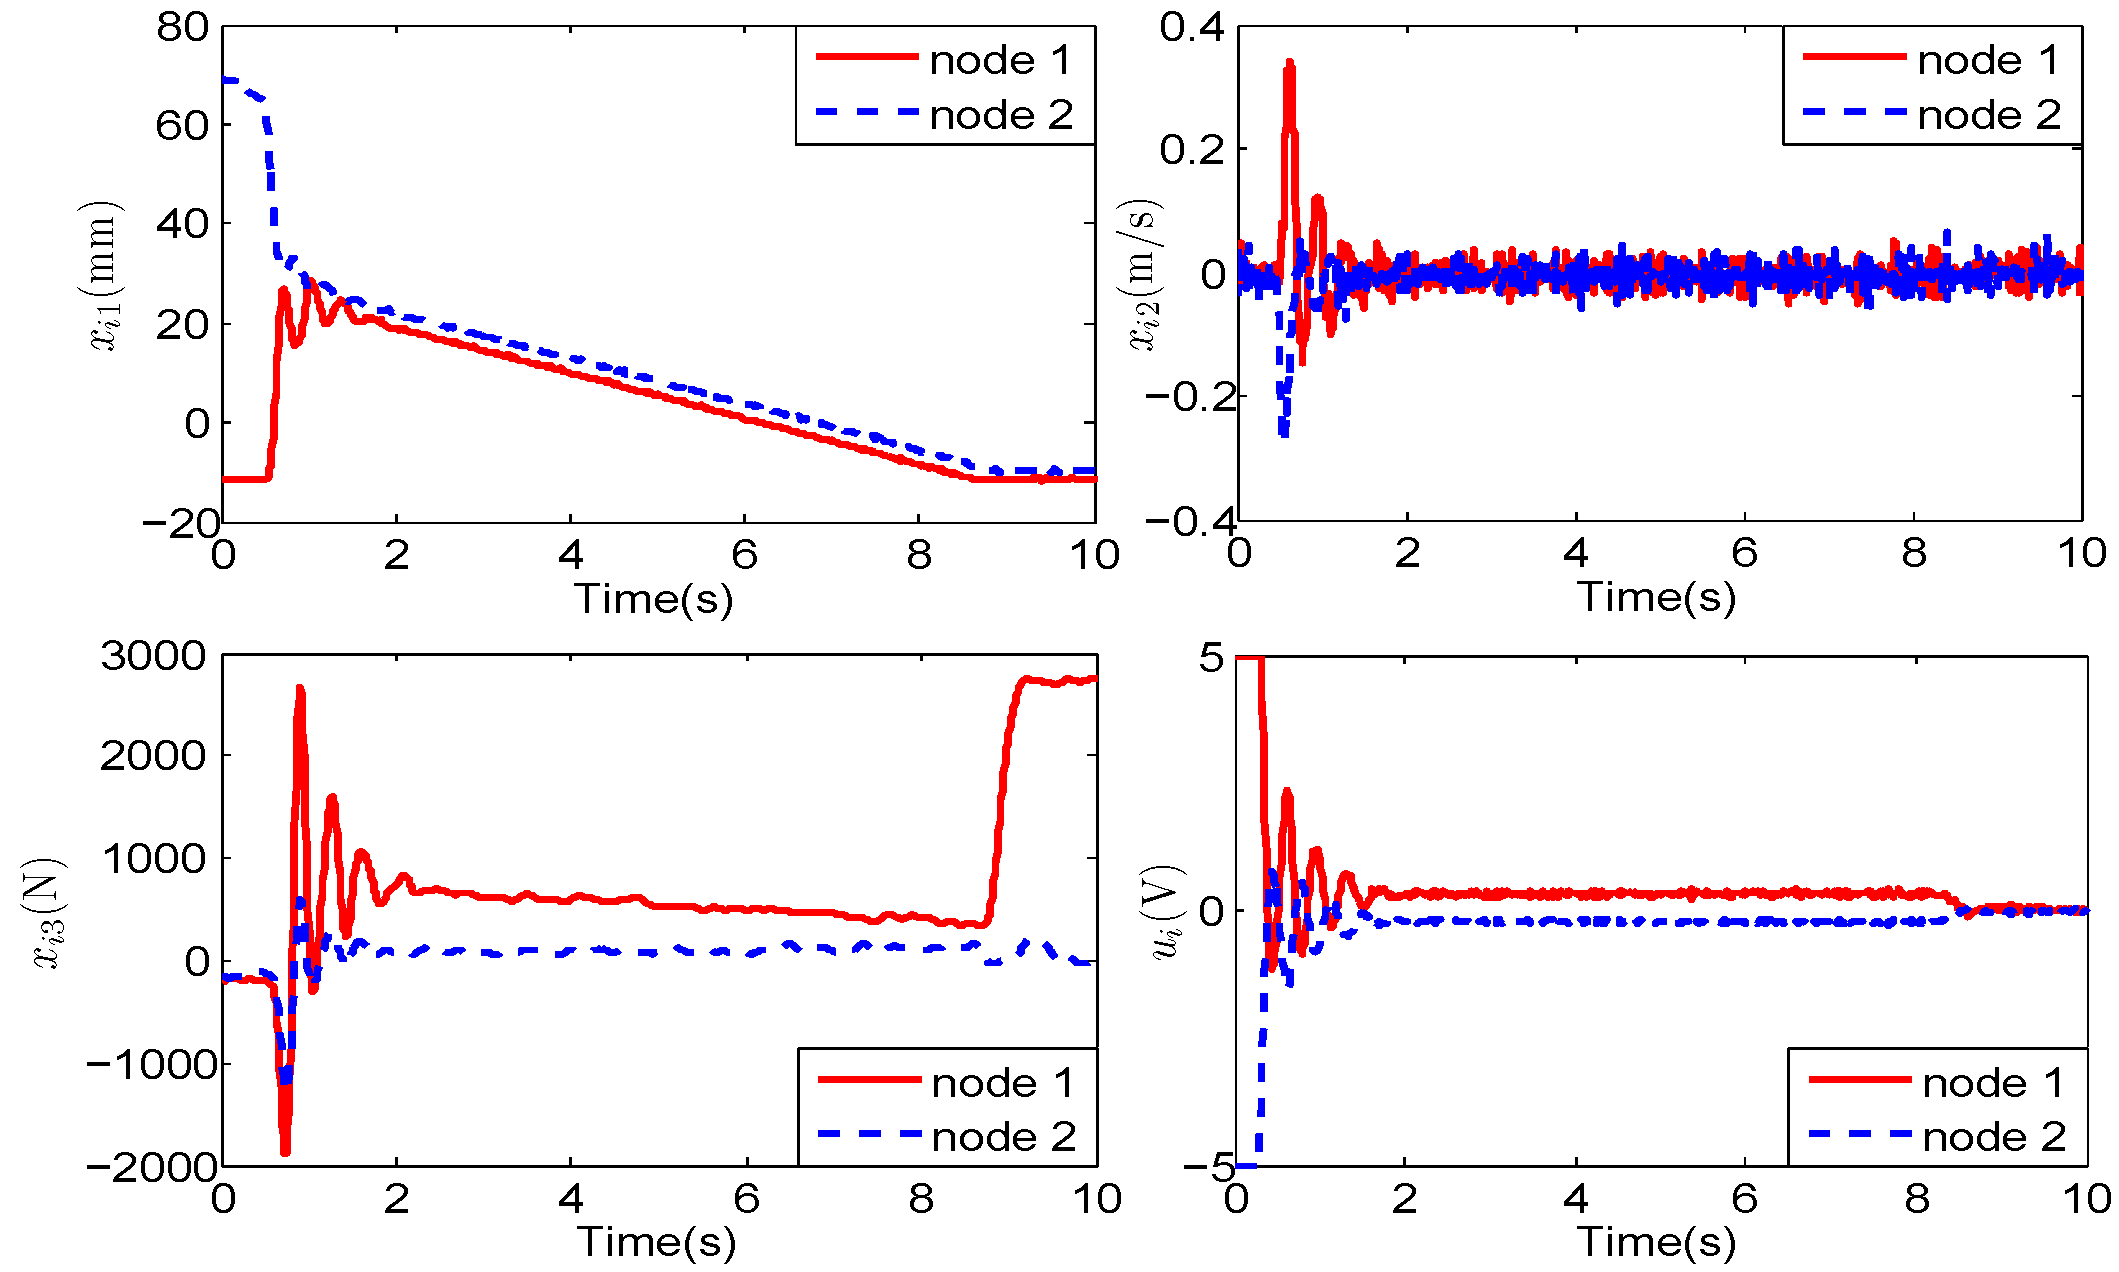
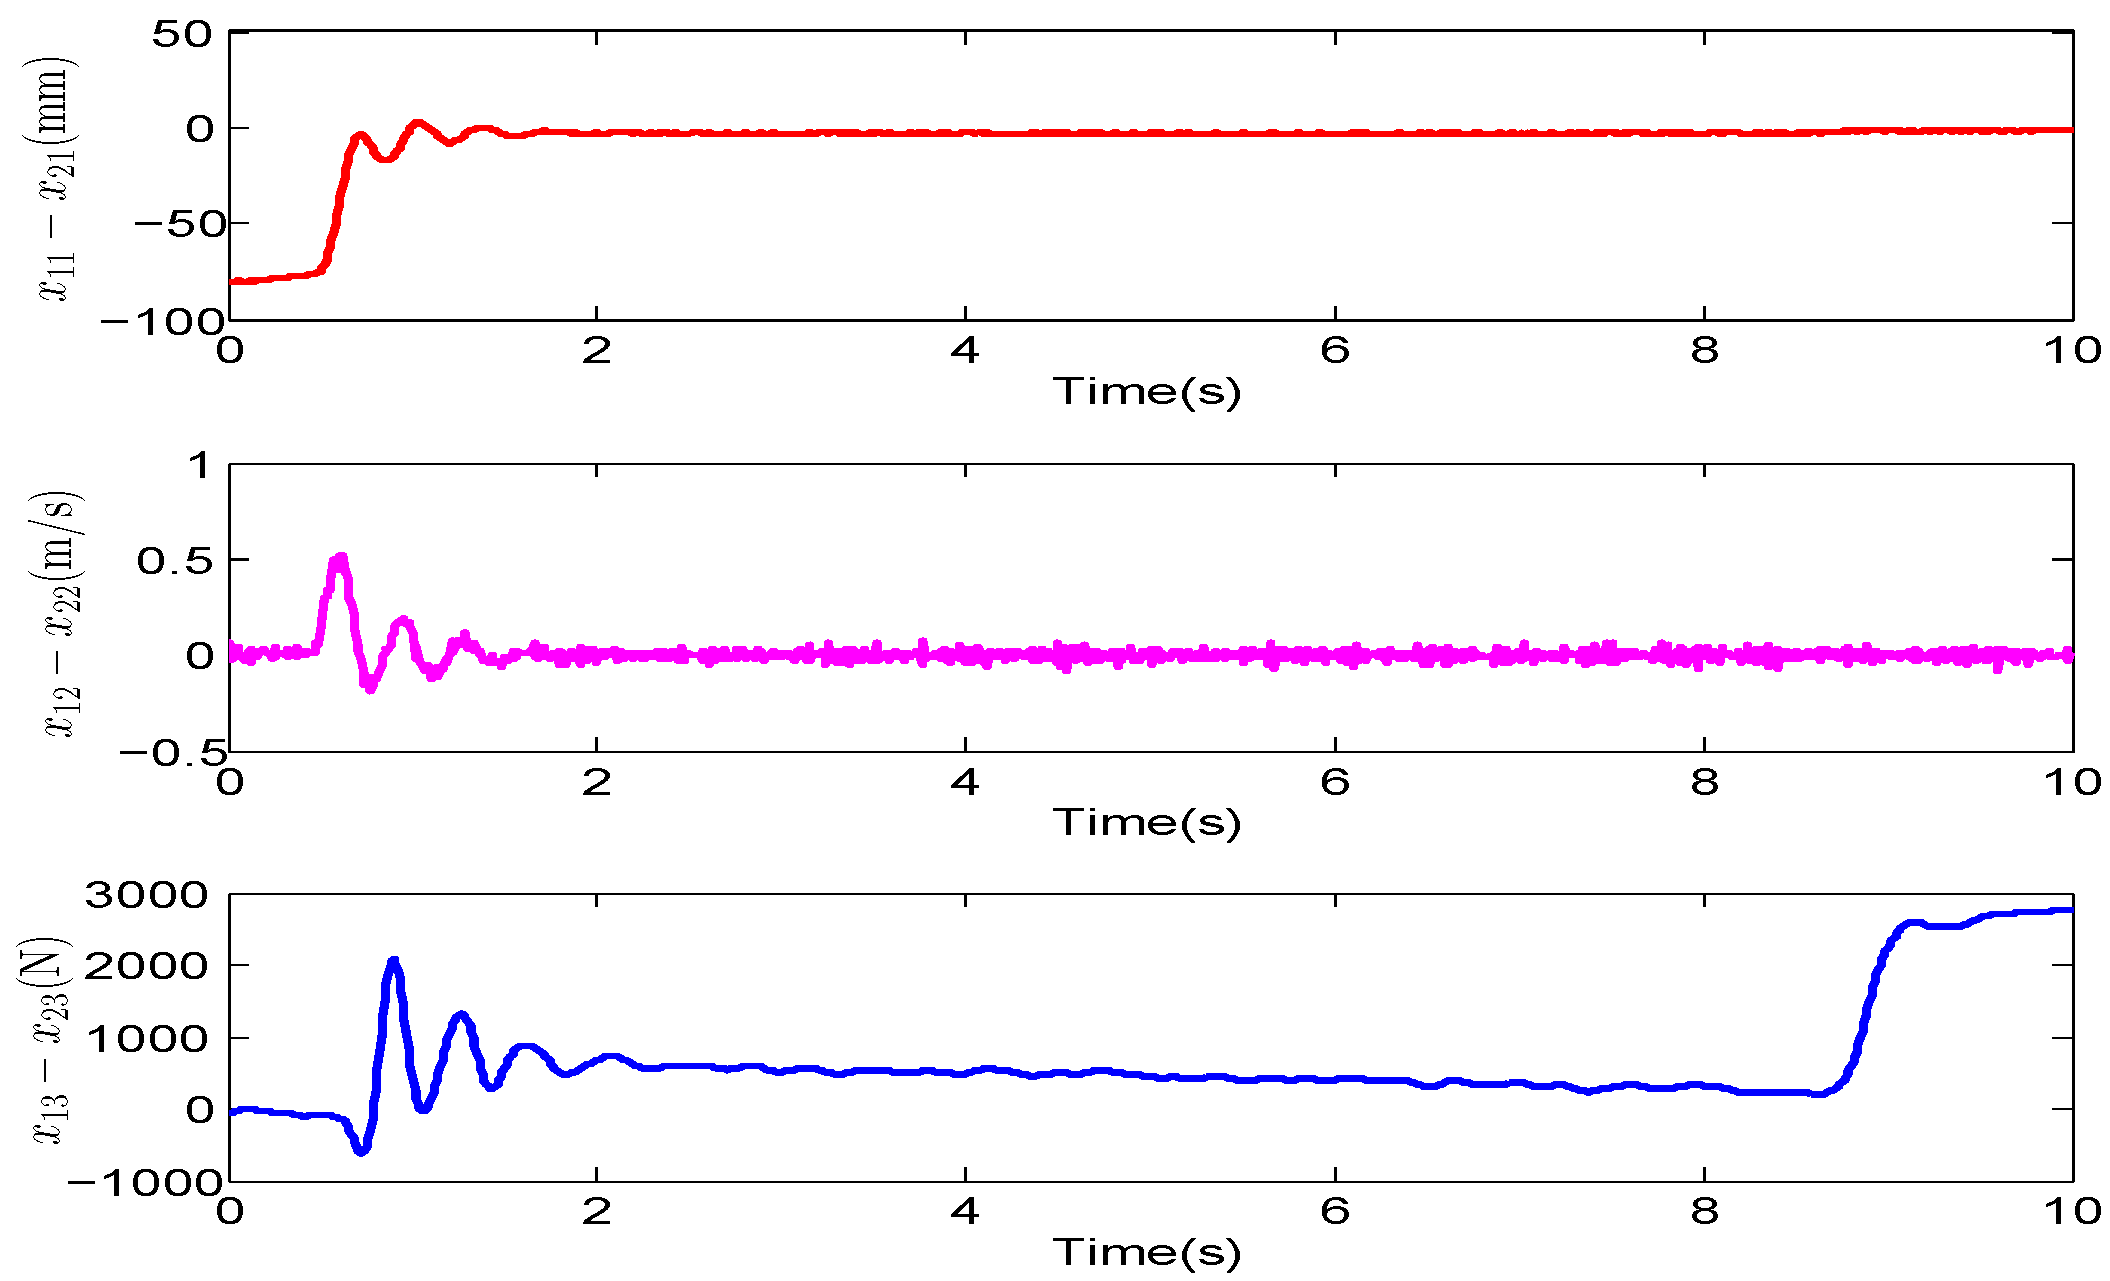
The MEHAs’ state responses of the two nodes in the experiment are shown in Figure 10. The nodes 1 and 2 EHAs drive the robotic upper arm and the forearm rotations, respectively. After 2 s, a consensus is achieved using the proposed synchronous control protocol. The steady-state pressures and of the two nodes are not close to zero since the existing external loads should be compensated for by from the driving force of the two robotic arms. Note that 8.5 s later, two cylinder positions gradually approach the zero point (mechanical balance state) due to the gravities of the two robotic arms. Meanwhile, the load pressure of the robotic upper arm is increased to hold the two static gravities of both robotic arms. Hence, the load pressure errors of the two nodes are of greater magnitudes than the corresponding position and velocity errors , as shown in Figure 11. At the mechanical balance states, the control voltages of the servo valve are zero, which means that the two hydraulic flows are cut off to supply the constant load pressures for the respective gravities of the robotic arms.
Figure 10.
The MEHAs’ state responses with two nodes in the experiment: —the cylinder position; —the cylinder velocity; —the cylinder load pressure; —the control voltage of the servo valve.
Figure 11.
The MEHAs’ state errors of two nodes in the experiment: (the red line)—the cylinder position error; (the pink line)—the cylinder velocity error; (the blue line)—the cylinder load pressure error.
5.2. Experimental Comparison Results
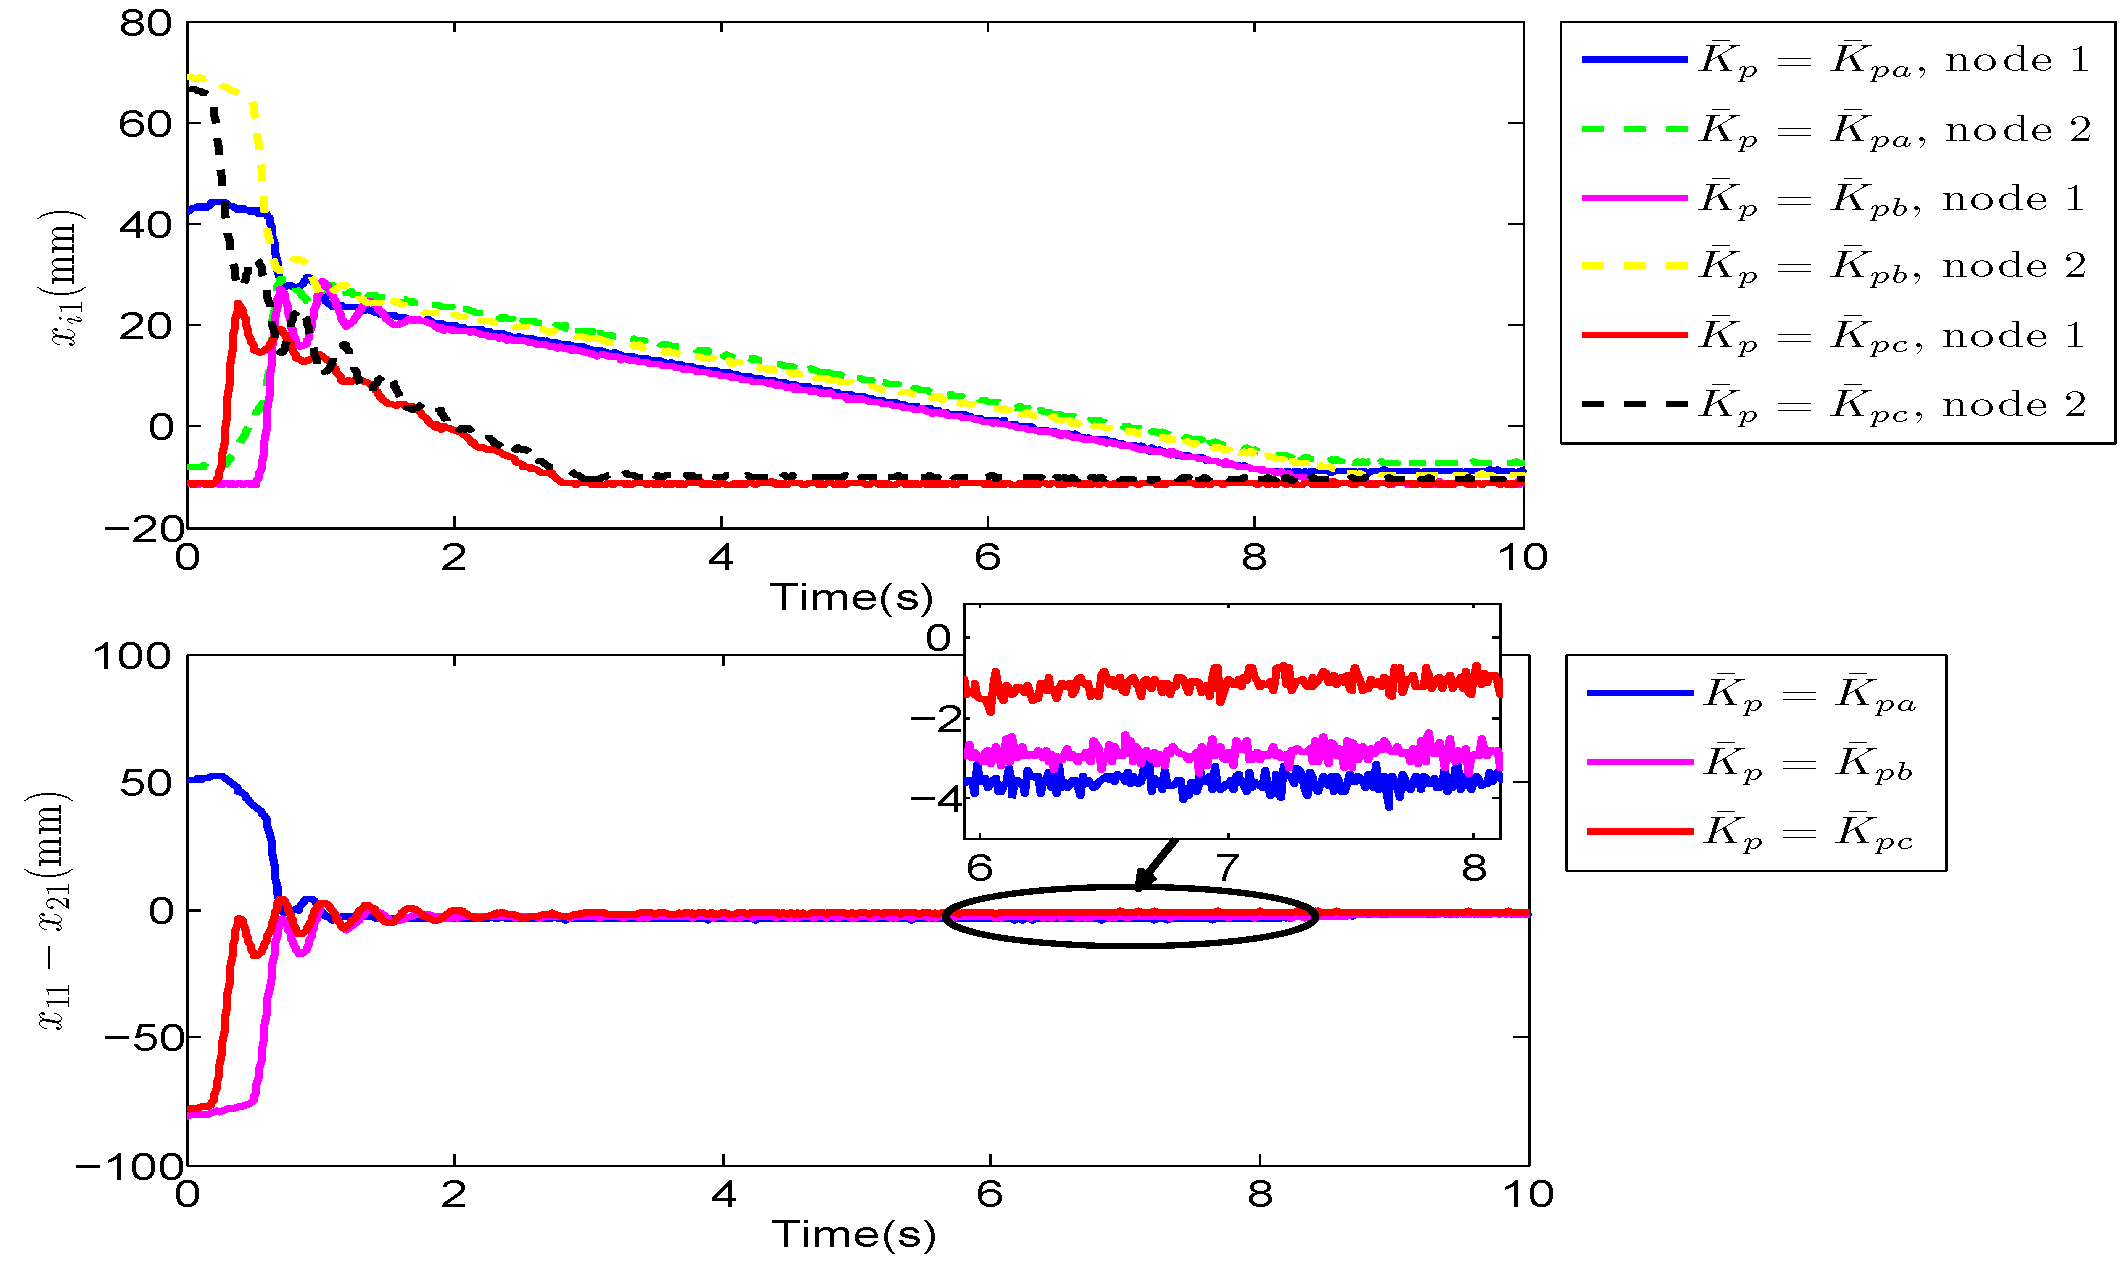
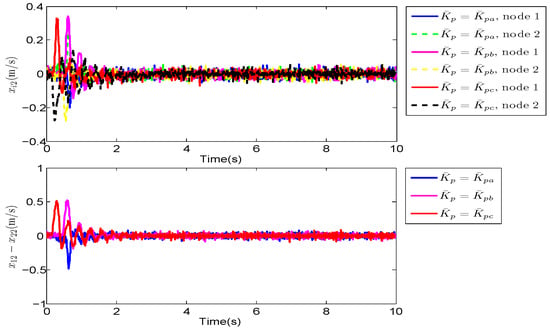
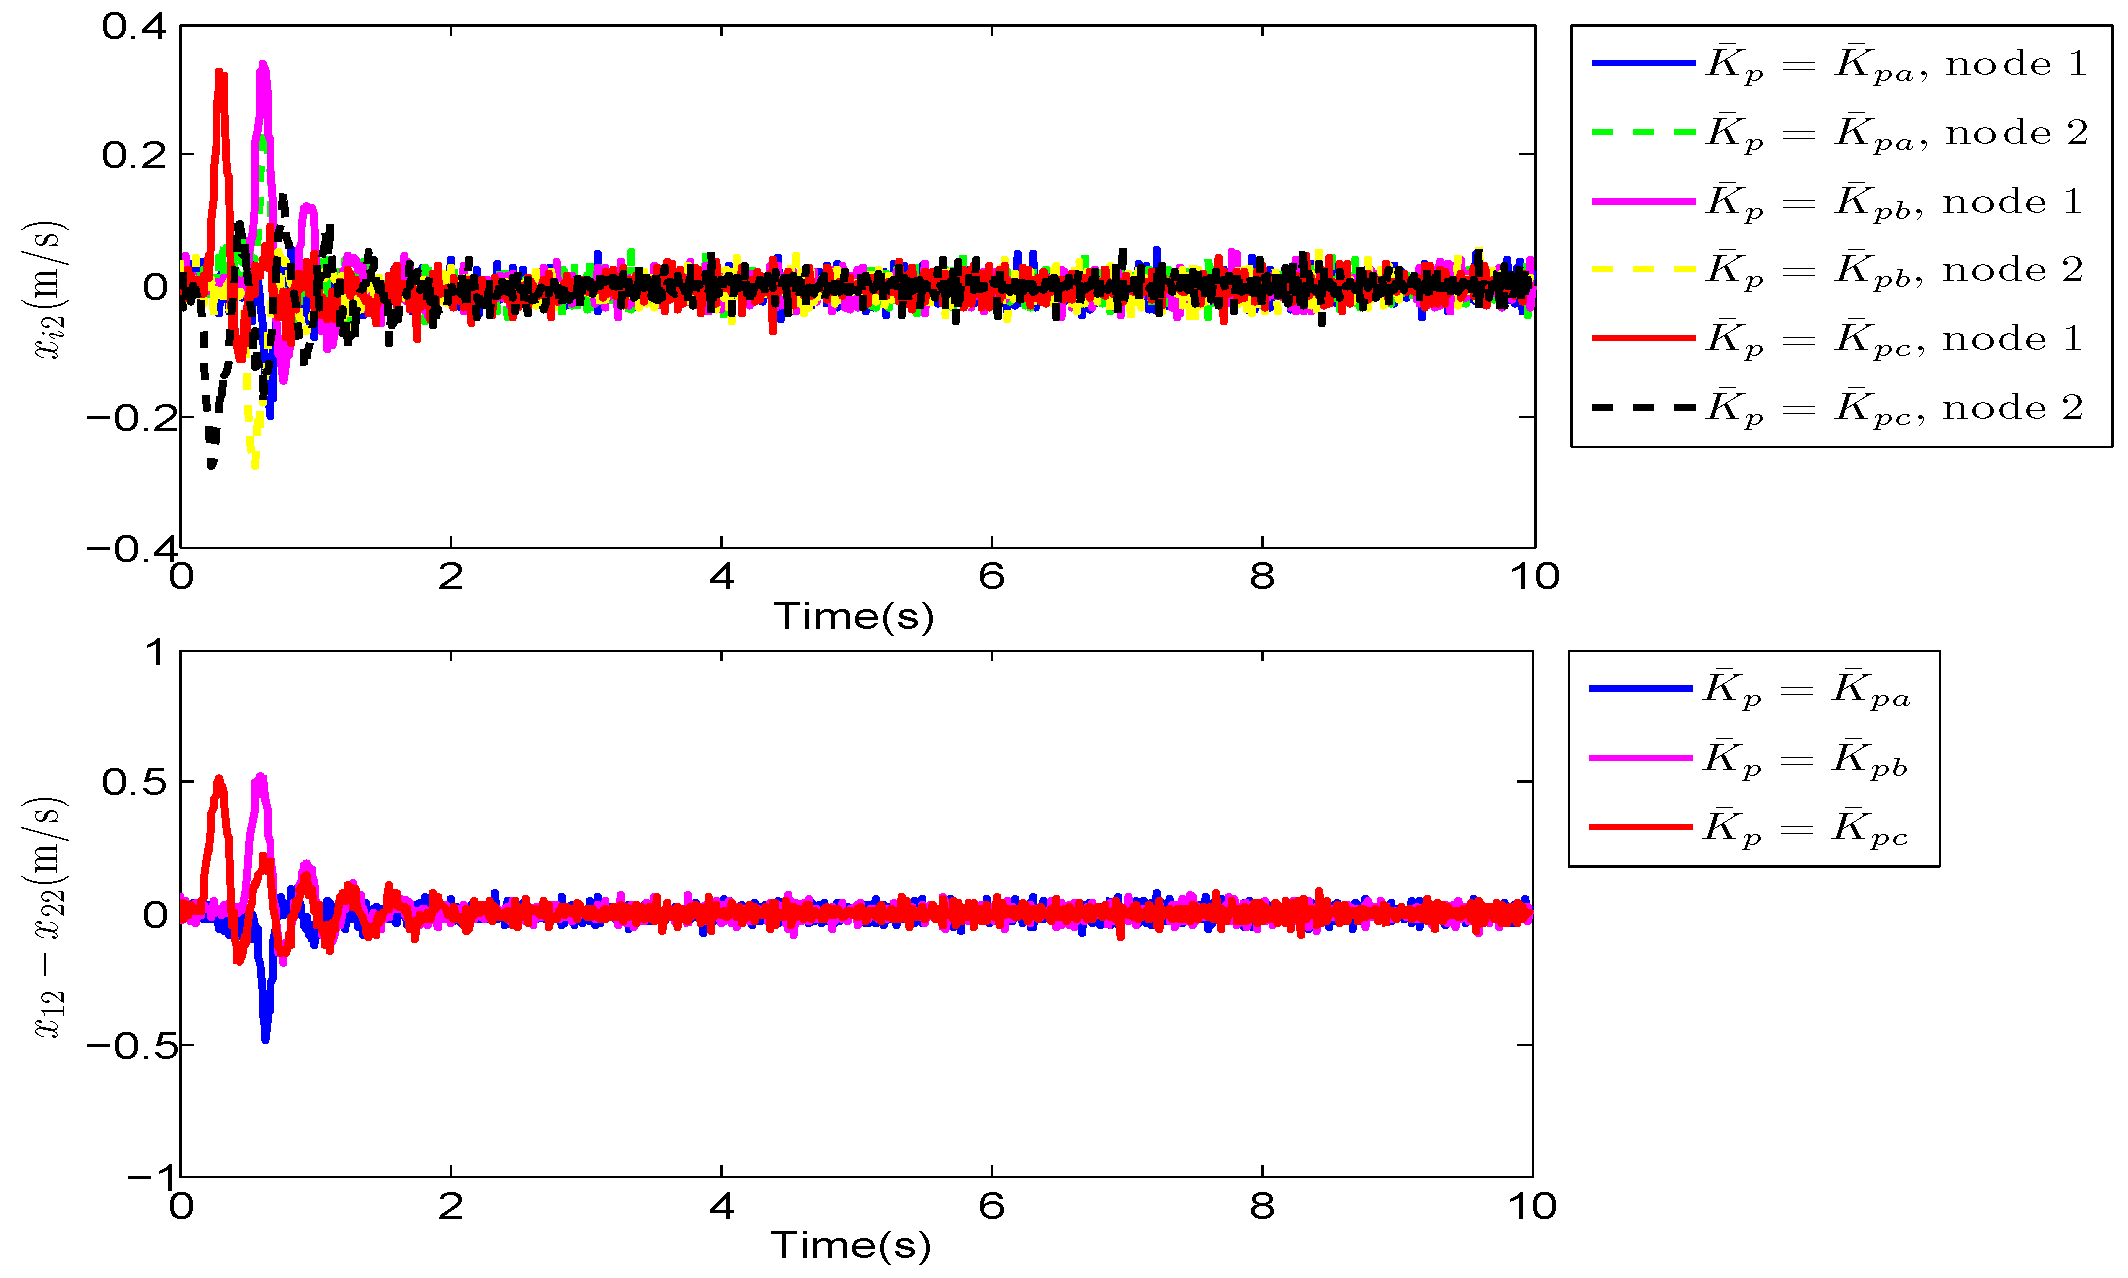
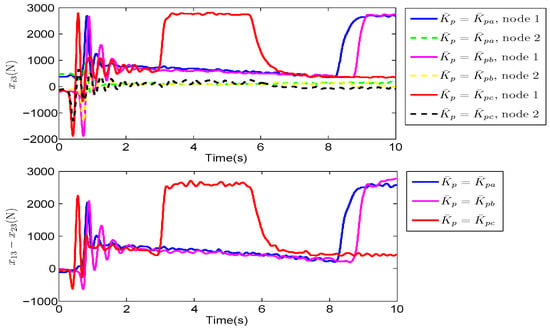
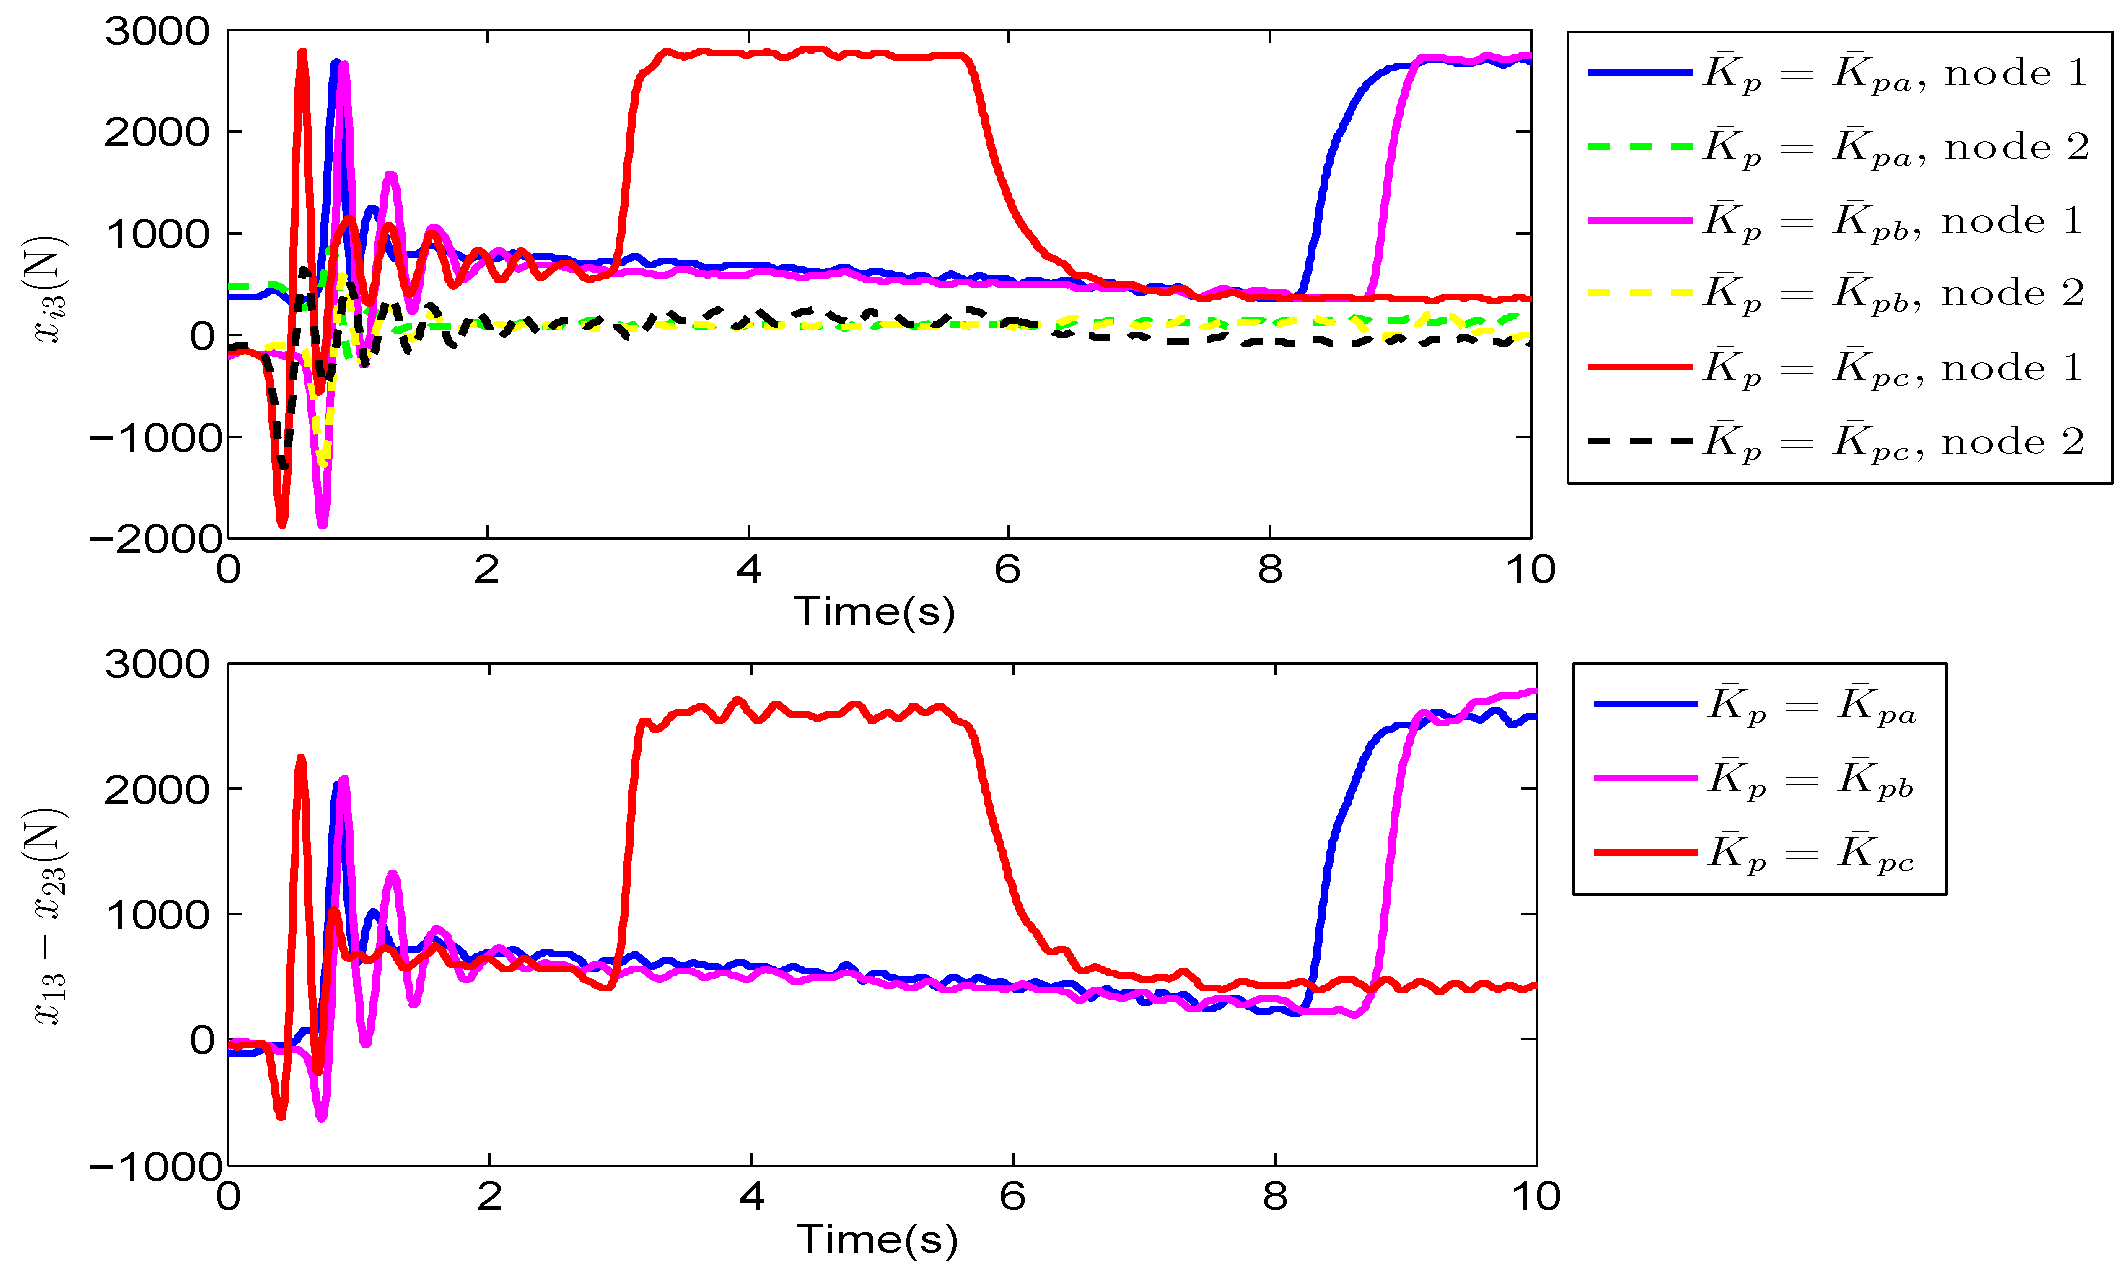
Similar to the simulation comparison, the other two state-feedback matrices are selected as and . Certainly, the corresponding initial state values could also be selected as (1) mm, mm/s, N, mm, mm/s, and N; (2) mm, mm/s, N, mm, mm/s, and N. The corresponding comparative state responses are shown in Figure 12, Figure 13 and Figure 14. Since the state-feedback matrix had the largest gain elements, its consensus rate was faster than the other two conditions, which is consistent with the simulation. Meanwhile, the steady-state error mm with respect to the largest matrix gain verified the effectiveness of the proposed synchronous control protocol. The steady velocity values of the two nodes entirely approached zero for the three conditions, as shown in Figure 13. Note that in the fast-response condition (i.e., ), the load pressure error of the two nodes was quickly reduced from 2600 N to 400 N, as shown in Figure 14, since the supply pressure of the hydraulic pumps was relieved by the relief valve. This operation can reduce the scattering loss of the EHSS.
Figure 12.
The compared position response results of the three state-feedback matrices using pole placement in the experiment.
Figure 13.
The compared velocity response results of the three state-feedback matrices using pole placement in the experiment.
Figure 14.
The compared pressure response results of the three state-feedback matrices using pole placement in the experiment.
6. Conclusions
In this study, a synchronous controller is used in multiple electrohydraulic actuators to realize the average consensus of every EHA node based on undirected graph theory. The feedback linearization model of the EHA with external load disturbance is set up to derive the linear state space model of MEHAs. Then, the synchronous control protocol is designed based on undirected network topology. Finally, a two-DOF robotic bench is set up to verify the effectiveness of the distributed control scheme. To be honest, the EHA nodes in this study are not adequate due to the robotic bench constraints. However, the proposed synchronous control method can be promoted in general mechatronic systems driven by multiple electrohydraulic actuators based on graph theory and cooperative control protocol. In the future, distributed synchronous control will be investigated based on directed spanning-tree topology and communication delays.
Author Contributions
J.Q. was in charge of the writing of this article; Q.G. and Y.Y. conceived and designed the architecture of this paper; H.R. corrected the text; Z.C. and D.J. performed the simulations and experiments. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the Sichuan Science and Technology Program (Grant No. 2022JDRC0018 and 2022YFG0341).
Conflicts of Interest
The authors declare no conflict of interest.
Nomenclature
| Discharge coefficient of the servo valve | |
| w | Area gradient of the servo valve |
| , | Supply pressure and return pressure |
| Load pressure of the hydraulic cylinder | |
| Density of the hydraulic oil | |
| Total leakage coefficient of the hydraulic cylinder | |
| Effective bulk modulus | |
| Annulus area of the hydraulic cylinder chamber | |
| Total volume of the hydraulic power mechanism | |
| K | Spring stiffness coefficient of the hydraulic cylinder |
| m, b | Load mass and viscous damping coefficients |
| External load of the electrohydraulic system | |
| , u | Gain and control voltage of the servo valve |
| ⊗ | Kronecker product for the matrix |
| Identity matrix with n orders |
References
- Yang, Y.; Ma, L.; Huang, D. Development and repetitive learning control of lower limb exoskeleton driven by electro-hydraulic actuators. IEEE Trans. Ind. Electron. 2017, 64, 4169–4178. [Google Scholar] [CrossRef] [Scilit]
- Chen, G.; Wang, J.; Wang, S.; Zhao, J.; Shen, W. Compliance control for a hydraulic bouncing system. ISA Trans. 2018, 79, 232–238. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Semini, C.; Barasuol, V.; Goldsmith, J.; Frigerio, M.; Focchi, M.; Gao, Y.; Caldwell, D.G. Design of the hydraulically actuated, torque-controlled quadruped robot HyQ2Max. IEEE/ASME Trans. Mechatronics 2017, 22, 635–646. [Google Scholar] [CrossRef] [Scilit]
- Koivumäki, J.; Mattila, J. Stability-guaranteed impedance control of hydraulic robotic manipulators. IEEE/ASME Trans. Mechatronics 2017, 22, 601–612. [Google Scholar] [CrossRef] [Scilit]
- Shen, G.; Zhu, Z.; Zhao, J.; Zhu, W.; Tang, Y.; Li, X. Real-time tracking control of electro-hydraulic force servo systems using offline feedback control and adaptive control. ISA Trans. 2017, 67, 356–370. [Google Scholar] [CrossRef] [Scilit]
- Guo, Q.; Chen, Z.; Shi, Y.; Yan, Y.; Guo, F. Synchronous control of multiple electrohydraulic actuators under distributed switching topologies with lumped uncertainty. J. Franklin Inst. 2022, 359, 4288–4306. [Google Scholar] [CrossRef] [Scilit]
- Yao, J.; Deng, W.; Sun, W. Precision motion control for electro-hydraulic servo systems with noise alleviation: A desired compensation adaptive approach. IEEE/ASME Trans. Mechatronics 2017, 22, 1859–1868. [Google Scholar] [CrossRef] [Scilit]
- Tran, D.T.; Ba, D.X.; Ahn, K.K. Adaptive backstepping sliding mode control for equilibrium position tracking of an electrohydraulic elastic manipulator. IEEE Trans. Ind. Electron. 2020, 67, 3860–3869. [Google Scholar] [CrossRef] [Scilit]
- Guo, Q.; Zuo, Z.; Ding, Z. Parametric adaptive control of single-rod electrohydraulic system with block-strict-feedback model. Automatica 2020, 113, 108807. [Google Scholar] [CrossRef] [Scilit]
- Yang, C.; Jiang, Y.; Li, Z.; He, W.; Su, C.Y. Neural control of bimanual robots with guaranteed global stability and motion precision. IEEE Trans. Ind. Informat. 2017, 13, 1162–1171. [Google Scholar] [CrossRef] [Scilit]
- Kim, W.; Shin, D.; Won, D.; Chung, C.C. Disturbance-observer-based position tracking controller in the presence of biased sinusoidal disturbance for Electrohydraulic actuators. IEEE Trans. Control Syst. Technol. 2013, 21, 2290–2298. [Google Scholar] [CrossRef] [Scilit]
- Guo, Q.; Chen, Z. Neural adaptive control of single-rod electrohydraulic system with lumped uncertainty. Mech. Syst. Signal Proc. 2021, 146, 106869. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Wei, J.; Guo, K.; Zhu, W. Nonlinear robust prediction control of hybrid active-passive heave compensator with extended disturbance observer. IEEE Trans. Ind. Electron. 2017, 64, 6684–6694. [Google Scholar] [CrossRef] [Scilit]
- He, W.; Meng, T.; Huang, D.; Li, X. Adaptive boundary iterative learning control for an Euler-Bernoulli beam system with input constraint. IEEE Trans. Neural Netw. Learn. Syst. 2018, 29, 1539–1549. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Guo, Q.; Zhang, Y.; Celler, B.G.; Su, S.W. Neural adaptive backstepping control of a robotic manipulator with prescribed performance constraint. IEEE Trans. Neural Netw. Learn. Syst. 2019, 30, 3572–3583. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zheng, D.; Xu, H. Adaptive backstepping-flatness control based on an adaptive state observer for a torque tracking electrohydraulic system. IEEE/ASME Trans. Mechatronics 2016, 21, 2440–2452. [Google Scholar] [CrossRef] [Scilit]
- Wang, N.; Xu, L.; Xie, F.; Shi, Y.; Wang, Y. Research on the dynamic characteristics of pneumatic proportional regulator in pneumatic-loading system and design of fuzzy adaptive controller. Sci. China Technol. Sci. 2022, 65, 956–965. [Google Scholar] [CrossRef] [Scilit]
- Ning, F.; Shi, Y.; Cai, Y.; Xu, W. Research and application progress of data mining technology in electric power system. J. Adv. Mfg. Sci. Technol. 2021, 1, 2021007. [Google Scholar] [CrossRef] [Scilit]
- Yao, J.; Di, D.; Jiang, G.; Gao, S.; Yan, H. Real-time acceleration harmonics estimation for an electro-hydraulic servo shaking table using Kalman Filter with a linear model. IEEE Trans. Control Syst. Technol. 2014, 22, 794–800. [Google Scholar] [CrossRef] [Scilit]
- Yang, C.; Qu, Z.; Han, J. Decoupled-space control and experimental evaluation of spatial electrohydraulic robotic manipulators using singular value decomposition algorithms. IEEE Trans. Ind. Electron. 2014, 61, 3427–3438. [Google Scholar] [CrossRef]
- Jafari, M.; Xu, H. A biologically-inspired intelligent controller for distributed velocity control of multiple electro-Hydraulic servo-systems. In Proceedings of the Symposium Series on Computational Intelligence, Honolulu, HI, USA, 27 November–1 December 2017. [Google Scholar]
- Cao, Y.; Yu, W.; Ren, W.; Chen, G. An overview of recent progress in the study of distributed multi-agent coordination. IEEE Trans. Autom. Control 2013, 9, 427–438. [Google Scholar] [CrossRef] [Scilit]
- Lawton, J.R.; Beard, R.W. Synchronized multiple spacecraft rotations. Automatica 2002, 38, 1359–1364. [Google Scholar] [CrossRef] [Scilit]
- Olfati-Saber, R.; Shamma, J.S. Consensus filters for sensor networks and distributed sensor fusion. In Proceedings of the IEEE Conference Decision Control & European Control Conference, Seville, Spain, 12–15 December 2015; pp. 6698–6703. [Google Scholar]
- Ren, W.; Beard, R.W. Information consensus in multivehicle cooperative control. IEEE Control Syst. Mag. 2007, 27, 71–82. [Google Scholar]
- Fax, J.A.; Murray, R.M. Information flow and cooperative control of vehicle formations. IEEE Trans. Autom. Control 2004, 49, 115–120. [Google Scholar] [CrossRef] [Scilit]
- Su, H.; Wang, X.; Lin, Z. Flocking of multi-agents with a virtual leader. IEEE Trans. Autom. Control 2009, 54, 293–307. [Google Scholar] [CrossRef] [Scilit]
- Olfati-Saber, R.; Fax, J.A.; Murray, R.M. Consensus and cooperation in networked multi-agent systems. Proc. IEEE 2007, 95, 215–233. [Google Scholar] [CrossRef] [Scilit]
- Hong, Y.; Hu, J.; Gao, L. Tracking control for multi-agent consensus with an active leader and variable topology. Automatica 2006, 42, 1177–1182. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Liu, X.; Ren, W.; Xie, L. Consensus control of linear multi-agent systems with distributed adaptive protocols. In Proceedings of the American Control Conference, Montreal, QC, Canada, 27–29 June 2012; pp. 1573–1578. [Google Scholar]
- Li, Z.; Ren, W.; Liu, X. Consensus of multi-agent systems with general linear and lipschitz nonlinear dynamics using distributed adaptive protocols. IEEE Trans. Autom. Control 2013, 58, 1786–1791. [Google Scholar] [CrossRef] [Scilit]
- Zhang, H.; Lewis, F.L. Adaptive cooperative tracking control of higher-order nonlinear systems with unknown dynamics. Automatica 2012, 48, 1432–1439. [Google Scholar] [CrossRef] [Scilit]
- Wen, G.; Duan, Z.; Yu, W.; Chen, G. Consensus of multi-agent systems with nonlinear dynamics and sampled-data information: A delayed-input approach. Int. J. Robust Nonlin. 2013, 23, 602–619. [Google Scholar] [CrossRef] [Scilit]
- Zuo, Z.; Lin, T. A new class of finite-time nonlinear consensus protocols for multi-agent systems. Int. J. Control Autom. 2014, 87, 363–370. [Google Scholar] [CrossRef] [Scilit]
- Ma, C.; Zhang, J. Necessary and sufficient conditions for consensusability of linear multi-agent systems. IEEE Trans. Autom. Control 2010, 55, 1263–1268. [Google Scholar]
- Yu, W.; Lewis, F.L. Some necessary and sufficient conditions for second-order consensus in multi-agent dynamical systems. Automatica 2010, 46, 1089–1095. [Google Scholar] [CrossRef] [Scilit]
- Lin, P.; Jia, Y. Average consensus in networks of multi-agents with both switching topology and coupling time-delay. Physica A 2008, 387, 303–313. [Google Scholar] [CrossRef] [Scilit]
- Xiao, F.; Wang, L. Asynchronous consensus in continuous-time multi-agent systems with switching topology and time-varying delays. IEEE Trans. Autom. Control 2008, 53, 1804–1816. [Google Scholar] [CrossRef] [Scilit]
- Wei, N.; Cheng, D. Leader-following consensus of multi-agent systems under fixed and switching topologies. Syst. Control. Lett. 2010, 59, 209–217. [Google Scholar]
- Wen, G.; Duan, Z.; Ren, W.; Chen, G. Distributed consensus of multi-agent systems with general linear node dynamics and intermittent communications. Int. J. Robust Nonlin. 2014, 24, 2438–2457. [Google Scholar] [CrossRef] [Scilit]
- Seo, J.; Shim, H.; Back, J. Consensus of high-order linear systems using dynamic output feedback compensator: Low gain approach. Automatica 2009, 45, 2659–2664. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Duan, Z.; Chen, G.; Huang, L. Consensus of multiagent systems and synchronization of complex networks: A unified viewpoint. IEEE Trans. Circuits I 2010, 57, 213–224. [Google Scholar]
- Li, Z.; Liu, X.; Lin, P.; Ren, W. Consensus of linear multi-agent systems with reduced-order observer-based protocols. Syst. Control. Lett. 2011, 60, 510–516. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Wen, G.; Duan, Z.; Ren, W. Designing fully distributed consensus protocols for linear multi-agent systems with directed graphs. IEEE Trans. Autom. Control 2015, 60, 1152–1157. [Google Scholar] [CrossRef] [Scilit]
- Su, H.; Chen, G.; Wang, X.; Lin, Z. Adaptive second-order consensus of networked mobile agents with nonlinear dynamics. Automatica 2011, 47, 368–375. [Google Scholar] [CrossRef] [Scilit]
- Guo, Q.; Chen, Z.; Shi, Y.; Li, X.; Yan, Y.; Guo, F.; Li, S. Synchronous control for multiple electrohydraulic actuators with feedback linearization. Mech. Syst. Signal Proc. 2022, 178, 109280. [Google Scholar] [CrossRef] [Scilit]
- Merritt, H. Hydraulic Control Systems; John Wiley & Sons: New York, NY, USA, 1967. [Google Scholar]
- Khalil, H.K. Nonlinear Systems, 3rd ed.; Prentice Hall: Upper Saddle River, NJ, USA, 2002. [Google Scholar]
- Ren, W.; Beard, R.W. Distributed Consensus in Multi-Vehicle Cooperative Control Theory and Applications; Springer: London, UK, 2008. [Google Scholar]
Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).