


Featured Application
This work can be applied to predictive maintenance and intelligent fault prognosis of rolling-bearing-supported rotating machinery. The proposed method is particularly suitable for industrial scenarios requiring robust and interpretable remaining useful life prediction under noisy signals, variable operating conditions, and near-failure degradation stages.
Abstract
Accurate remaining useful life (RUL) prediction of rolling bearings was essential for condition-based maintenance because bearing service degradation was primarily governed by progressive rolling-contact fatigue at the rollingelement–raceway interface, whereas vibration signals provided measurable responses to this degradation rather than being its physical cause. However, reliable RUL prediction remained challenging because vibration measurements were noisy, nonlinear, stage-dependent, and sensitive to operating-condition shifts. In this study, a health-indicator-guided temporal-attention framework was developed for bearing RUL prediction using public run-to-failure vibration datasets. The novelty of this work lay in integrating degradation-consistent health indicator construction, sliding-window life-cycle representation, and HI-guided temporal attention into a unified and interpretable prediction framework. First, degradation-sensitive vibration features were extracted and fused into a compact health indicator (HI) to represent the progressive deterioration trend. Then, sliding-window sequences were generated and processed by a Transformer-based temporal-attention network, through which long-range temporal dependencies were captured and higher weights were assigned to informative degradation segments near stage transitions and late-life acceleration. Experiments on the XJTU-SY and IMS datasets showed that the proposed method improved prediction stability, reduced late-life error amplification, and achieved better performance than baseline variants without HI or temporal attention. Ablation analysis confirmed that HI construction mitigated cross-stage drift, whereas temporal attention enhanced transition sensitivity during accelerated degradation. Robustness and cross-domain tests further indicated that the method maintained acceptable degradation-following behavior under noise perturbations and operating-condition changes, although explicit domain-adaptation mechanisms were still required for strongly shifted target domains.
1. Introduction
Rolling bearings were key load-carrying and motion-transmission components in rotating machinery such as motors, gearboxes, pumps, turbines, and machine-tool spindles. Their service life was mainly limited by progressive rolling-contact fatigue and surface/subsurface damage at the rollingelement–raceway interface. Under repeated contact loading, fatigue cracks could initiate and propagate, eventually producing local defects, pitting, spalling, contact-stiffness variation, and dynamic excitation. Therefore, vibration have been understood as a measurable response and monitoring indicator of progressive bearing contact degradation, rather than as the fundamental cause of bearing failure. Classical bearing fatiguelife theory and tribological analysis showed that rolling-contact fatigue, lubrication condition, contact stress, material response, and interface dynamics jointly governed bearing life evolution [1,2]. In industrial practice, vibration monitoring was widely adopted because fatigue-induced local defects and contact irregularities generated transient impulses, amplitude/frequency modulation, and non-stationary vibration signatures. These signals provided useful information for condition-based maintenance and remaining useful life (RUL) prediction, but their interpretation remained difficult because they were affected by load, speed, sensor configuration, acquisition system, and noise level. Bearing-induced vibration in high-speed spindle systems also showed that vibration responses should be attributed to their mechanical sources, including bearing defects, contact dynamics, assembly conditions, and operating states [3].
Existing bearing RUL prediction methods were broadly categorized into model-based and data-driven paradigms. Model-based methods relied on physical degradation models and predefined failure mechanisms, which were useful when the system mechanism and degradation parameters were clearly known. However, they often faced difficulties in capturing complex real-world degradation processes involving multiple stages, uncertain fault evolution, and variable operating environments. In contrast, data-driven methods became increasingly prominent because they learned degradation patterns directly from historical vibration data. Chen et al. [4] reviewed transfer-learning-based bearing RUL prediction methods from an industrial application perspective and emphasized the importance of generalization under practical operating scenarios. Wei et al. [5] introduced a self-adaptive graph convolutional network with a self-attention mechanism for bearing RUL prediction, showing the potential of attention-based representation learning. Kim and Park [6] proposed a semi-supervised transfer learning method based on an anti-self-healing health indicator, while Xu et al. [7] developed a health-indicator-weighted subdomain alignment network to improve RUL prediction across operating conditions. These studies indicated that degradation representation quality and cross-condition adaptability were essential for reliable bearing prognostics.
To improve nonlinear temporal modeing, many studies had integrated convolutional extraction, recurrent learning, and attention mechanisms into hybrid deep architectures. Najdi et al. [8] proposed an adaptive Res-LSTM attention-based model for rolling bearing lifetime prognosis. Jin et al. [9] employed a TCN–Transformer network to jointly capture local temporal dependencies and long-range sequence relationships from vibration signals. Qu et al. [10] designed a deep time–frequency synergistic memory neural network to enhance degradation information mining in both temporal and spectral domains. Sun et al. [11] developed a CBAM-CNN-LSTM model, and Xu et al. [12] proposed a dual-channel regression fusion network, both aiming to improve feature extraction and regression stability. Mohajerzarrinkelk et al. [13] further explored a multi-channel Swin Transformer framework for bearing RUL prediction. In addition, Wu et al. [14] systematically reviewed deep-learning-based RUL prediction methods and highlighted that robustness, interpretability, and generalization remained major challenges in this field.
Another important research direction addressed cross-domain generalization and stage-wise degradation evolution. Wang et al. [15] proposed an interactive learning strategy for bearing RUL prediction, suggesting that dynamic representation refinement benefited life forecasting. Yang et al. [16] introduced a CNN-VAE-MBiLSTM framework to enhance latent degradation representation. Li et al. [17] combined CNN-Bi-LSTM with domain adaptation to reduce the effect of distribution mismatch across datasets. Under variable operating conditions, Hou et al. [18] proposed a cross-transformer framework with segmented data cleaning, and Gao et al. [19] developed a long-term temporal attention neural network with adaptive stage division. Wu et al. [20] incorporated temporal multi-resolution hypergraph attention for bearing RUL prediction, Zhang et al. [21] proposed a weighted time embedding Transformer network, and Zhong et al. [22] developed a multi-region hypergraph self-attention network. More recently, He et al. [23] introduced a two-stage updated digital twin framework, He et al. [24] proposed DCAGGCN, and Lei et al. [25] combined hierarchical clustering with Transformer-GRU for bearing RUL prediction. These studies showed that temporal dependency modelling, stage-aware representation, and cross-domain robustness had become central issues in bearing prognostics.
Recent studies on vibration-based monitoring had also emphasized the importance of signal preprocessing and accelerometric information for fault detection. Niola et al. [26] investigated torque/speed equilibrium point monitoring of an aircraft hybrid electric propulsion system using accelerometric signal processing, showing that vibration-derived information supported condition monitoring in complex rotating systems. Helm and Timusk [27] applied wavelet denoising to rolling element bearing fault detection, demonstrating that denoising and preprocessing were important for extracting reliable degradation-related information from noisy bearing signals. These studies further indicated that robust vibration representation was a prerequisite for reliable bearing fault diagnosis and RUL prediction.
Entropy-based descriptors were also widely used for vibration-based fault diagnosis and degradation representation because they quantified the complexity, irregularity, and non-stationarity of mechanical signals. Compared with conventional time-domain statistics, entropy measures provided complementary information for detecting changes in dynamic patterns during incipient degradation. Dispersion entropy was introduced as an efficient measure of time-series regularity and showed advantages in characterizing amplitude and frequency variations in nonlinear signals [28]. Its multiscale and improved variants were also applied to rotating machinery fault diagnosis, indicating their potential for non-stationary degradation characterization [29]. In bearing prognostics, entropy-based descriptors were combined with sliding-window analysis to track the temporal evolution of degradation features and to transform continuous vibration streams into supervised sequential samples for RUL prediction.
Although existing studies improved bearing RUL prediction through deep learning, attention mechanisms, transfer learning, and health-indicator modelling, several knowledge gaps remained. First, many data-driven methods learned degradation patterns directly from vibration measurements, but the physical relationship between rolling-contact fatigue progression and vibration-based degradation representation was often insufficiently clarified. Second, existing RUL models achieved good average accuracy in certain benchmark settings but remained sensitive to stage transitions, late-life acceleration, and transient vibration disturbances, which caused amplified errors near failure. Third, variable operating conditions introduced distribution shifts in vibration amplitude, frequency composition, impulsiveness, degradation rate, and health-indicator trajectory, while many models still lacked an explicit mechanism to maintain stable prediction under sensor, speed, load, and noise variations. These gaps indicated the need for an interpretable degradation representation that connected vibration responses with bearing deterioration and a temporal model that emphasized informative degradation fragments during stage transitions and late-life evolution.
To address these issues, this study developed a health-indicator-guided temporal-attention framework for rolling bearing RUL prediction. The proposed framework differed from conventional sequence-learning models in three aspects. First, a degradation-oriented health indicator (HI) was constructed from vibration features to provide a compact and physically interpretable representation of progressive bearing deterioration, rather than allowing the model to learn only from high-dimensional raw or weakly structured features. Second, sliding-window life-cycle samples were used to preserve chronological degradation evolution and to connect local vibration responses with window-level RUL labels. Third, an HI-guided cross-attention mechanism was designed so that the HI stream provided degradation-trend guidance while the feature stream provided detailed vibration evidence, enabling the model to emphasize informative degradation fragments around regime transitions and late-life acceleration. The proposed method was evaluated on public run-to-failure bearing datasets under in-domain, noise-perturbed, cross-operating-condition, and cross-dataset settings. These evaluations examined not only prediction accuracy but also late-life stability, robustness, and generalization under realistic distribution shifts.
2. Methods
2.1. Notation Table
Table 1 summarized the main symbols used throughout this study. These notations covered the complete modeling pipeline, including raw vibration signals, slice-wise feature extraction, sliding-window sample construction, health indicator representation, temporal encoding, cross-attention fusion, regression output, and training objective. The unified notation system provided a clear mathematical basis for the subsequent formulation of HI construction, temporal feature learning, and RUL prediction.
Table 1.
Notations used in the article.
2.2. Public Datasets and Sequence Sample Construction
This study used two publicly available run-to-failure bearing datasets, namely the XJTU-SY bearing dataset [30] and the IMS bearing dataset [31]. The XJTU-SY dataset was used as the primary benchmark for model development, in-domain testing, cross-operating-condition evaluation, and ablation analysis. It contained complete run-to-failure vibration records of 15 rolling element bearings collected under three operating conditions, and it provided a suitable basis for evaluating the proposed model under different speedload combinations. The IMS dataset was used as an external validation benchmark to examine cross-dataset generalization. It was provided by the Center for Intelligent Maintenance Systems, University of Cincinnati, and released through the NASA Prognostics Data Repository. Compared with the XJTU-SY dataset, the IMS dataset involved different experimental settings, acquisition conditions, and bearing test configurations; therefore, it was used to assess whether the proposed framework could preserve degradation-following behavior under dataset-level distribution shifts.
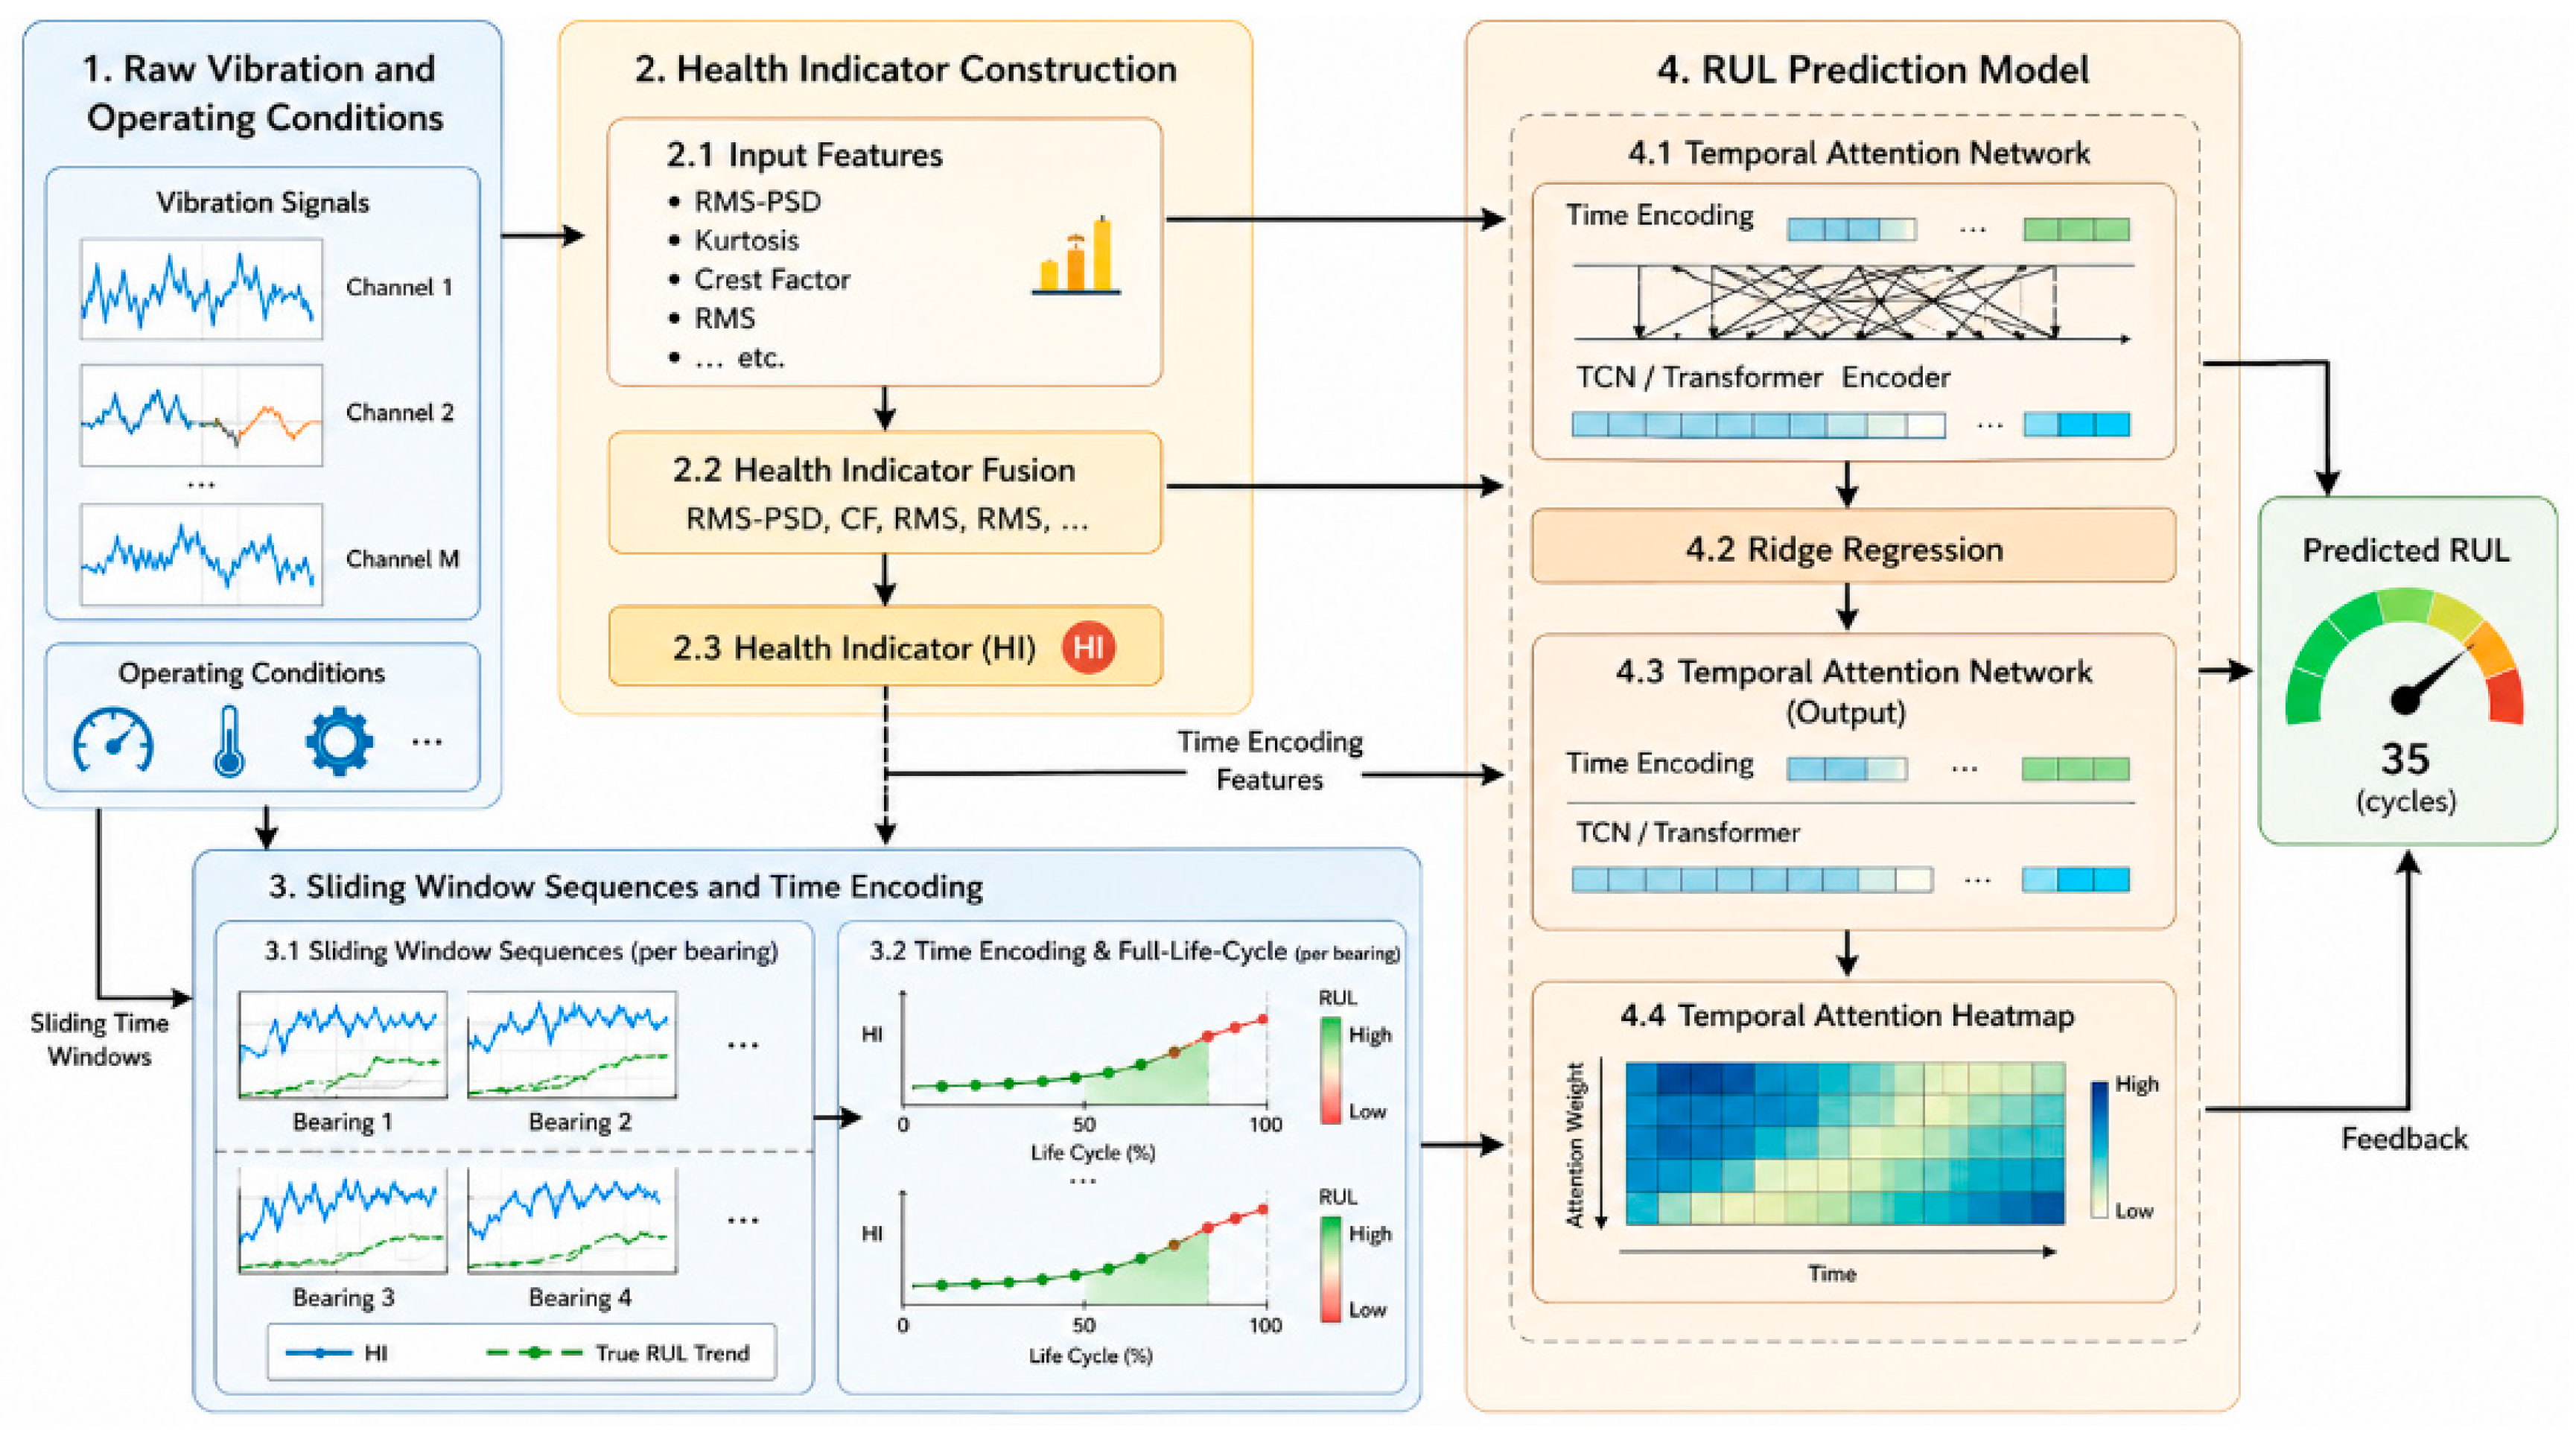
The overall workflow of the proposed HI-guided temporal-attention framework was illustrated in Figure 1. The framework started from full-life vibration signal acquisition and slice-wise feature extraction, followed by degradation-oriented HI construction, sliding-window sequence generation, temporal-attention modelling, and RUL regression. Therefore, Figure 1 clarified the methodological connection among raw vibration signals, constructed HI trajectories, temporal dependency modelling, and final RUL prediction.
Figure 1.
Overall framework of the HI-guided temporal-attention method for bearing RUL prediction.
To formulate remaining useful life prediction as supervised learning, the sliding-window strategy was used to construct training samples. For an end index , an input sequence was defined as:
where was the window length. The corresponding target label was the RUL at the window end time . Depending on the dataset specification, could be expressed in cycles, time, or normalized form. In this study, a consistent label definition was used across datasets by aligning the failure endpoint and representing RUL in a normalized scale , so that cross-condition and cross-dataset comparisons could be conducted under the same evaluation protocol.
To avoid information leakage, the data split was performed at the bearing level rather than the slice level. Specifically, all windows derived from the same bearing were assigned to the same subset, including the training, validation, or testing subset. This protocol ensured that the learned mapping generalized across bearings rather than memorizing local temporal correlations within a single life-cycle trajectory.
2.3. Feature Representation and Preprocessing
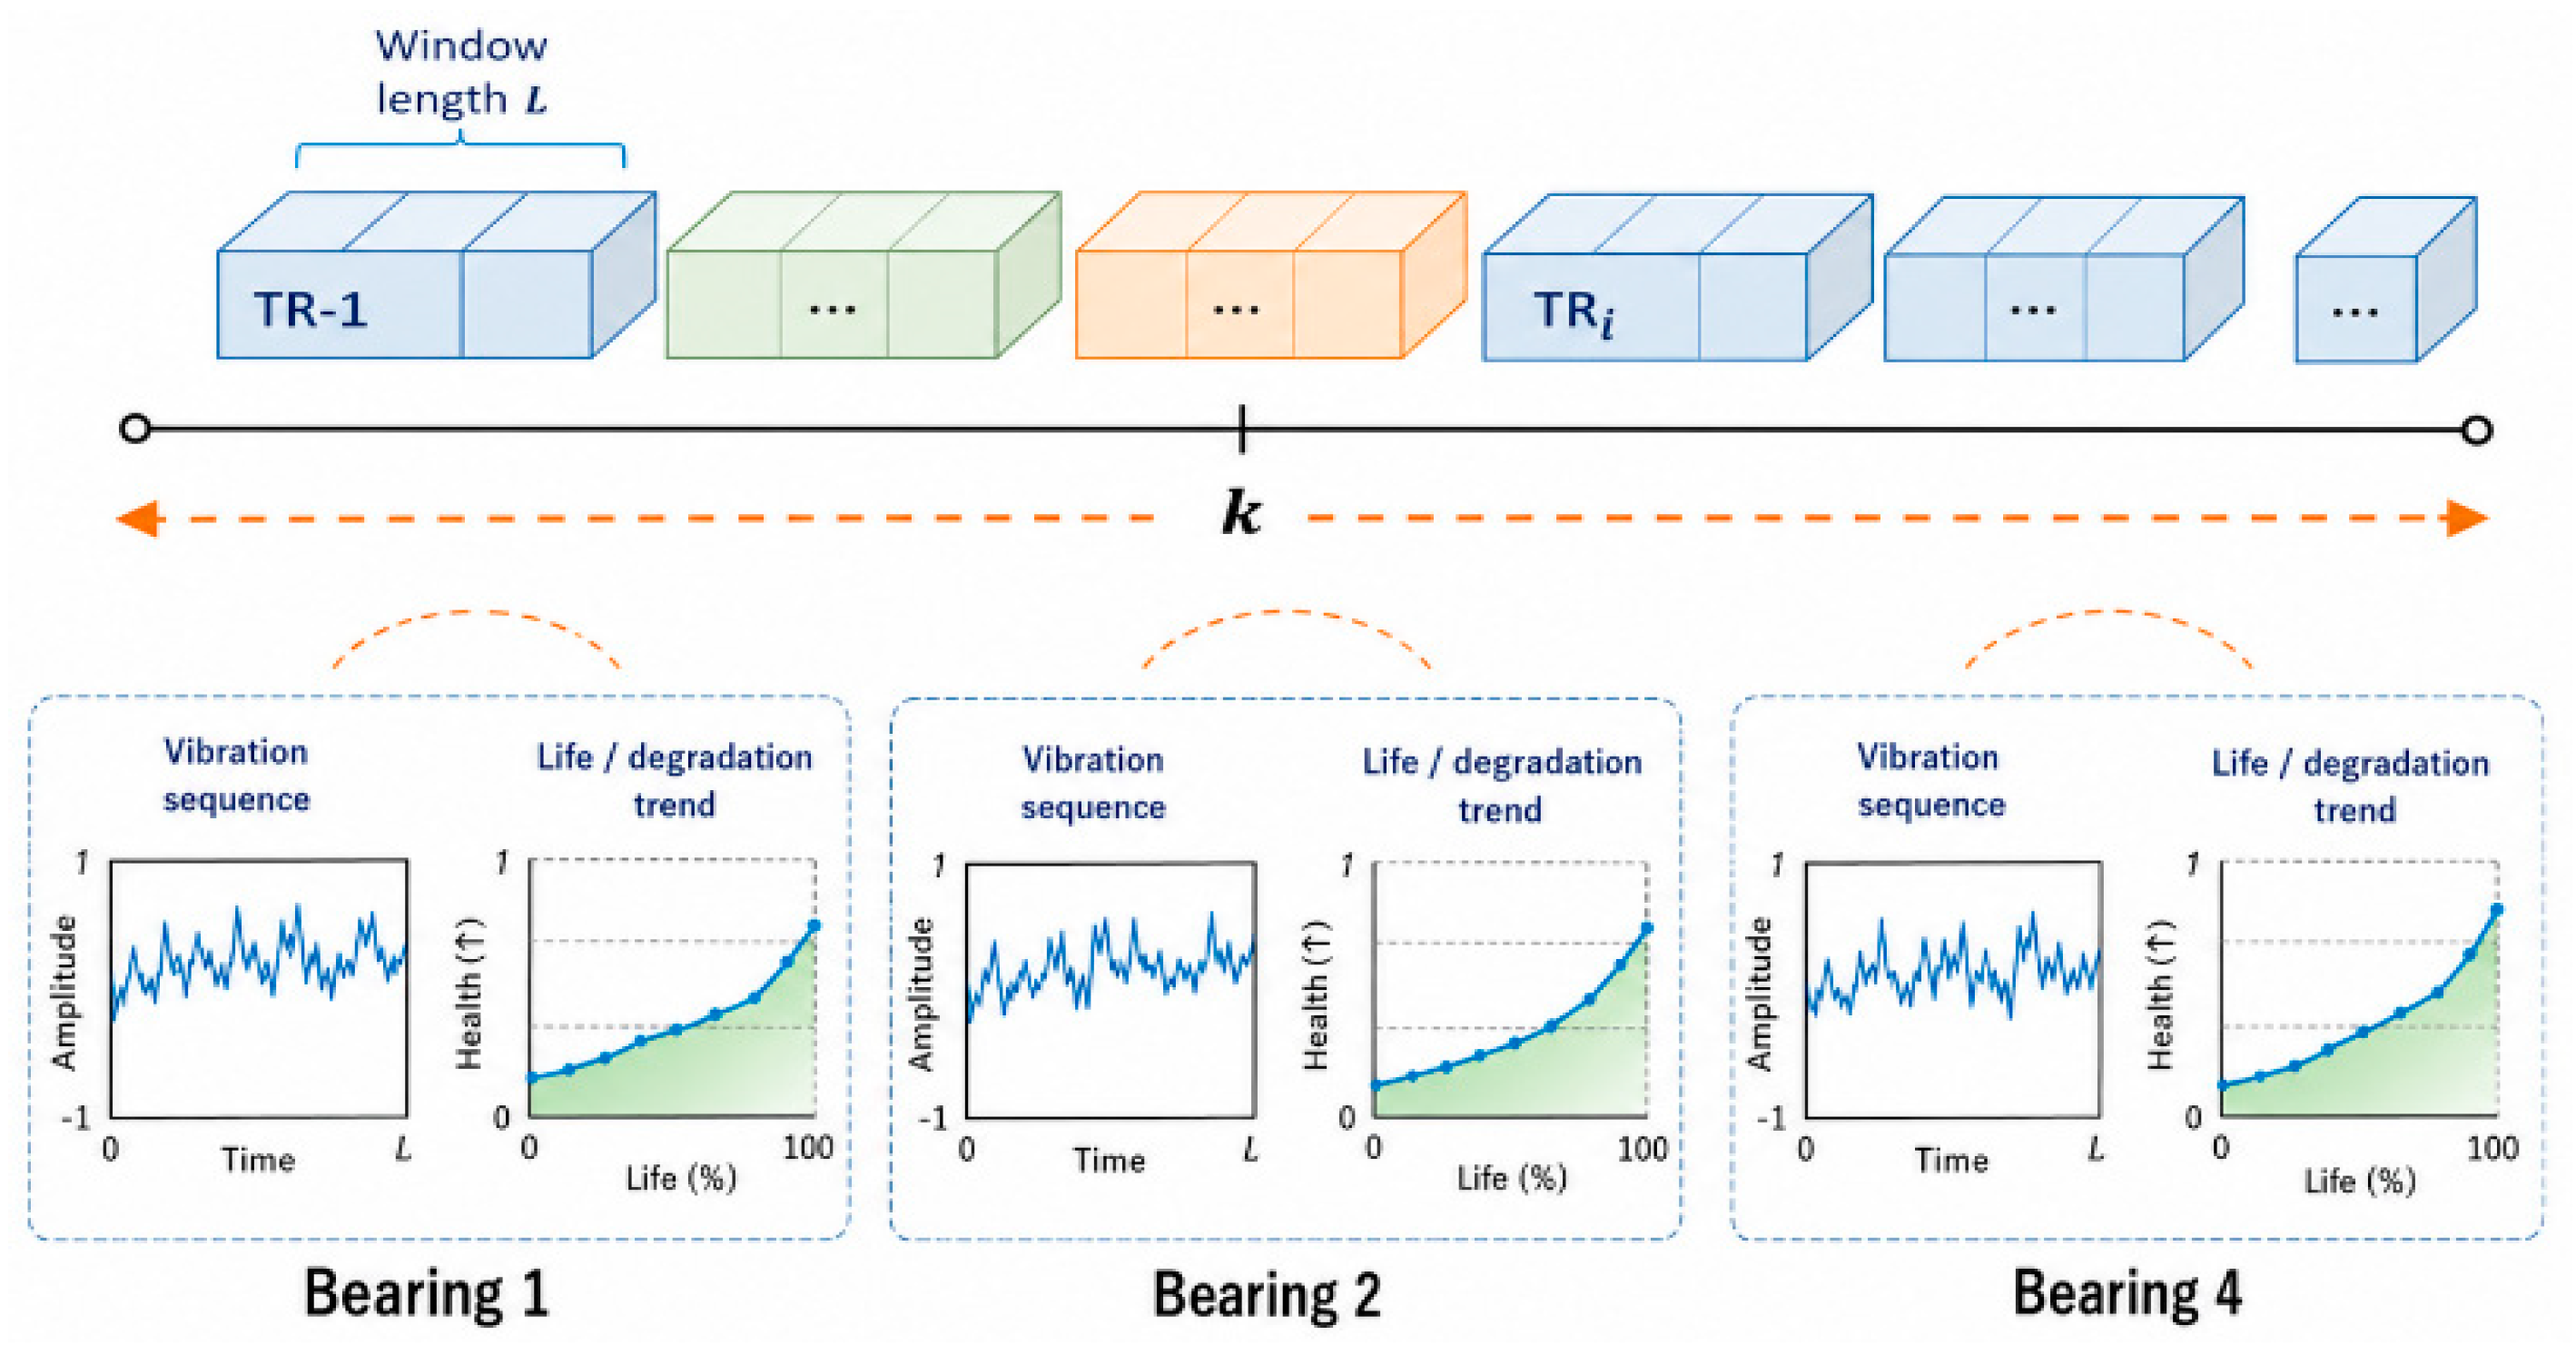
The sliding-window sample construction strategy is shown in Figure 2. For each bearing run-to-failure trajectory, overlapping windows were generated along the chronological degradation sequence. Each window was used as one input sample, and the RUL label was assigned according to the endpoint of the corresponding window. This design preserved the temporal order of degradation evolution and converted full-life vibration records into supervised samples for temporal modelling.
Figure 2.
Sliding-window sample construction and time encoding across bearing life-cycle trajectories.
Each slice was mapped to a compact descriptor that captured degradation-sensitive characteristics. The feature set integrated time-domain statistics, including root mean square, kurtosis, skewness, and crest factor; frequency-domain descriptors, including band energy derived from power spectral density; and distributional indicators that reflected impulsive behavior. Let denote the aggregated feature vector.
To improve training stability and reduce cross-bearing scale mismatch, features were standardized using statistics estimated from the training subset. Let and denote the training mean and standard deviation of the -th feature. The standardized feature was calculated as:
where was a small constant. In addition, lightweight smoothing and outlier suppression were applied to selected degradation-sensitive features to reduce sporadic spikes that did not reflect sustained degradation evolution. These preprocessing steps supported robust health indicator construction while preserving meaningful degradation transitions.
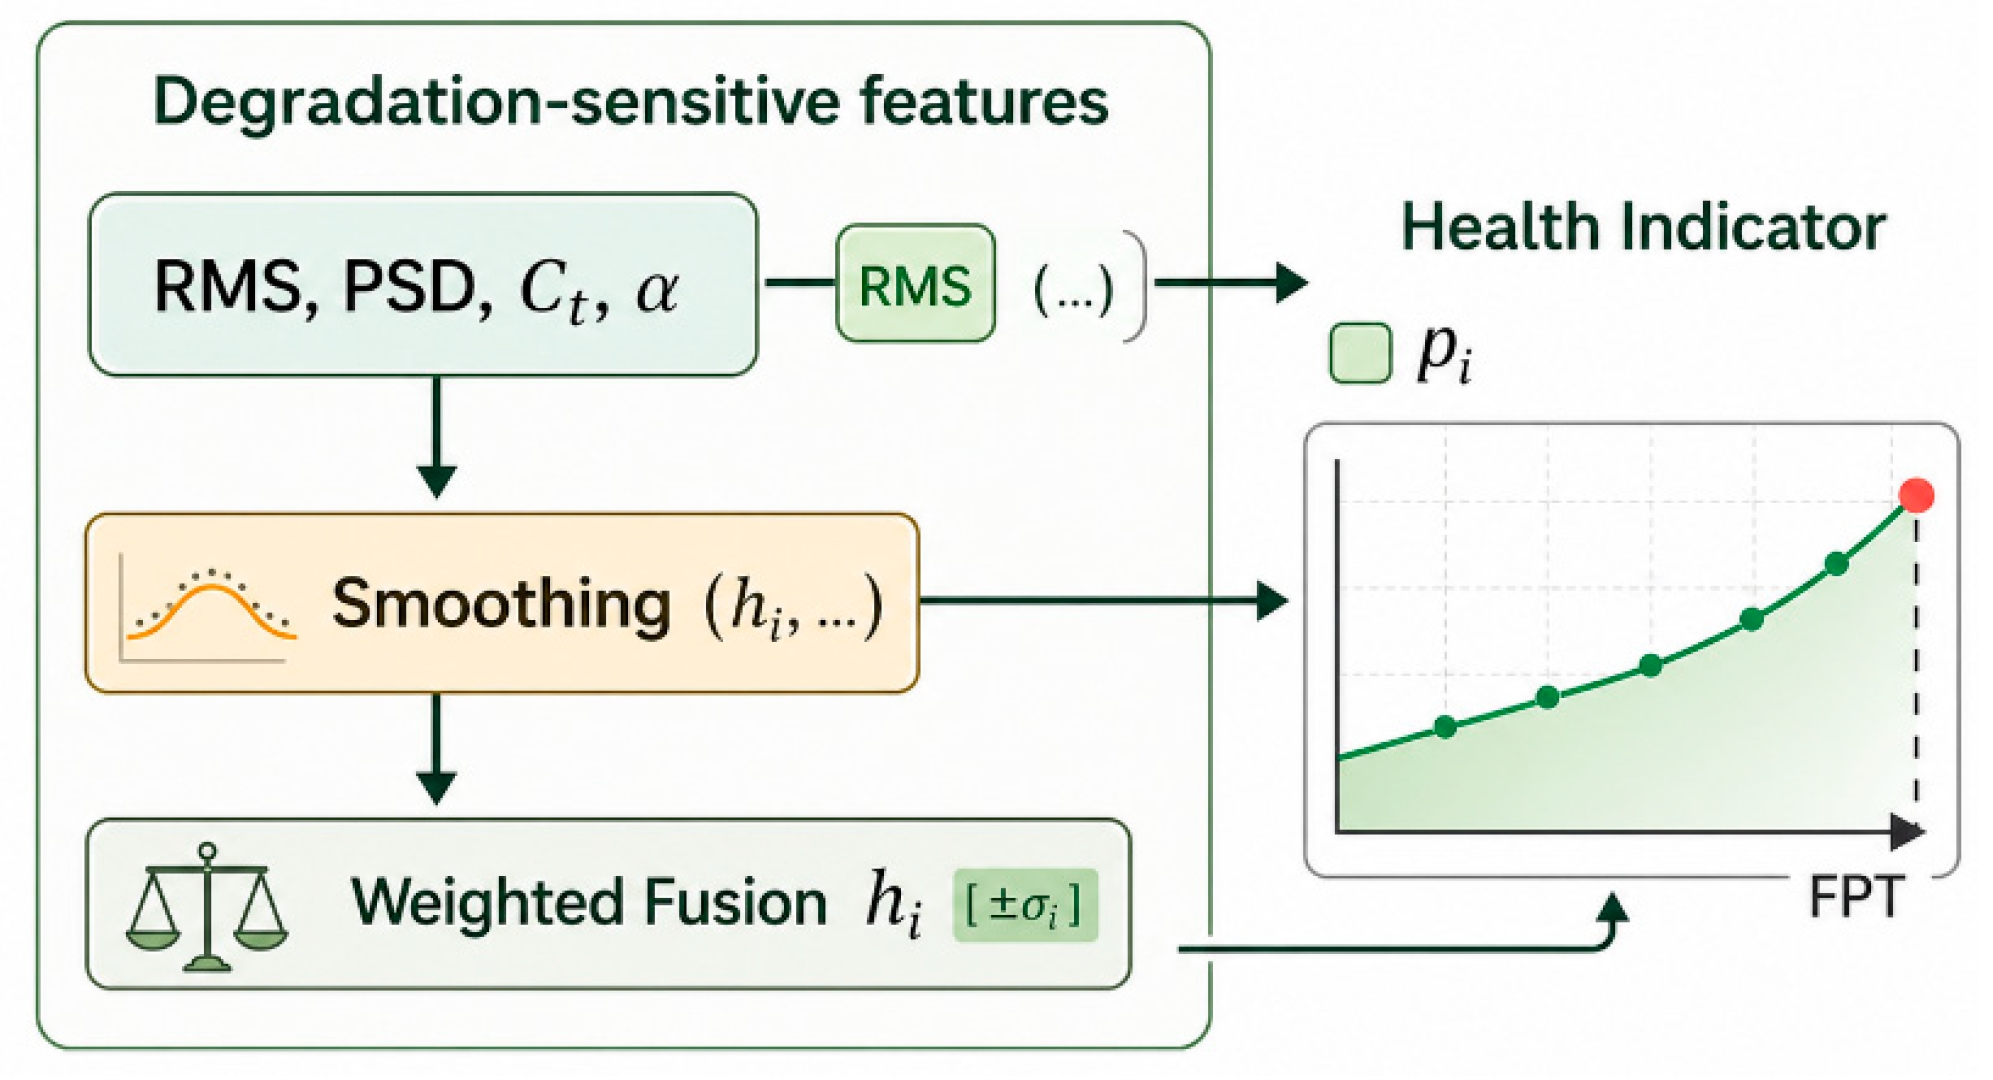
Figure 3 presented the construction procedure of the degradation-oriented HI. Multi-domain vibration features were first extracted from each signal slice, including time-domain, frequency-domain, and distribution-related descriptors. After standardization, degradation-sensitive features were selected and fused into a raw HI. Smoothing and quasi-monotonic constraints were then applied to suppress transient spikes and enhance degradation consistency. This process transformed high-dimensional vibration descriptors into a compact scalar trajectory that represented the global degradation trend of each bearing.
Figure 3.
Construction procedure of the degradation-oriented health indicator.
2.4. Health Indicator Construction with Degradation Constraints
A central goal of health indicator (HI) modeling is to transform multi-dimensional features into a scalar trajectory that reflects progressive degradation. An effective HI should exhibit stable behavior in the early stage and become increasingly degraded as the bearing approaches failure, thereby providing a compact representation for downstream RUL modeling. In this study, the HI was interpreted as a data-driven representation of fatigue-related vibration responses rather than a direct description of the physical fatigue process itself. This interpretation was consistent with the mechanical understanding that vibration responses were monitoring indicators of progressive rolling-contact degradation rather than the fundamental cause of bearing failure.
2.4.1. HI Fusion Model
Let denote a selected subset of standardized features that are empirically degradation-sensitive (e.g., RMS, kurtosis, high-frequency band energy). We define a raw HI by a fusion function :
The function can be implemented as a weighted linear fusion, a low-dimensional projection, or a shallow encoder. In practice, a weighted fusion offers transparency and stable behavior:
where controls the contribution of the -th degradation-sensitive component.
In the present implementation, the degradation-sensitive feature subset mainly included conventional time-domain statistics, frequency-domain energy descriptors, and impulsiveness-related indicators. Entropy-based descriptors, such as dispersion entropy and its multiscale variants, were closely related to non-stationary degradation characterization and could be incorporated into the same HI construction framework in future work. They were discussed in this study as relevant extensions rather than additional experimental modules, so that the reported results remained consistent with the implemented feature set.
2.4.2. Smoothing and Monotonicity Regularization
Because bearing signals can contain transient disturbances, the raw HI is smoothed to emphasize persistent degradation trends:
To enforce physically plausible degradation evolution, a monotonic or quasi-monotonic constraint is imposed. A simple and effective construction is the cumulative maximum operator which guarantees non-decreasing HI values along time.
2.4.3. Incipient Degradation Point
To further enhance interpretability, an incipient degradation point (first predictive time, FPT) can be estimated from the HI slope change. Let . An FPT candidate can be detected by a threshold on slope deviation:
where and are computed from an initial stable period and is a sensitivity coefficient. With , staged consistency can be enforced by requiring low variability before and sustained degradation after . This staged constraint is not required for model training but is valuable for HI validation and qualitative analysis.
2.5. Temporal Encoding and Cross-Attention Network for RUL Prediction
This section introduces a temporal attention network that explicitly integrates (i) the multi-dimensional feature sequence and (ii) the scalar HI sequence, enabling cross-guided representation learning. The key design is a cross-attention fusion mechanism that allows HI dynamics to guide the model’s focus on informative time steps, especially near the late-life stage where prediction is most challenging.
2.5.1. Temporal Position Encoding
Given a window , we first apply a temporal position encoding to preserve order information. Let denote the positional embedding. The embedded feature tokens are:
where maps input features to a hidden dimension (e.g., linear layer). Similarly, the HI tokens within the same window are formed as
where and is a learnable projection to dimension . This shared temporal encoding aligns the two streams in the same time reference.
2.5.2. Dual-Branch Temporal Encoders
Two temporal encoders are used to model intra-stream dependencies:
where . The encoder can be instantiated as a lightweight Transformer encoder, a temporal convolution block, or a gated recurrent module. The dual-branch design ensures that the feature stream captures rich degradation-related patterns while the HI stream captures compact trend dynamics.
2.5.3. Cross-Attention Fusion
To emphasize the cross-guided property, we perform cross-attention between the HI branch and the feature branch. Specifically, HI representations serve as queries and feature representations serve as keys and values:
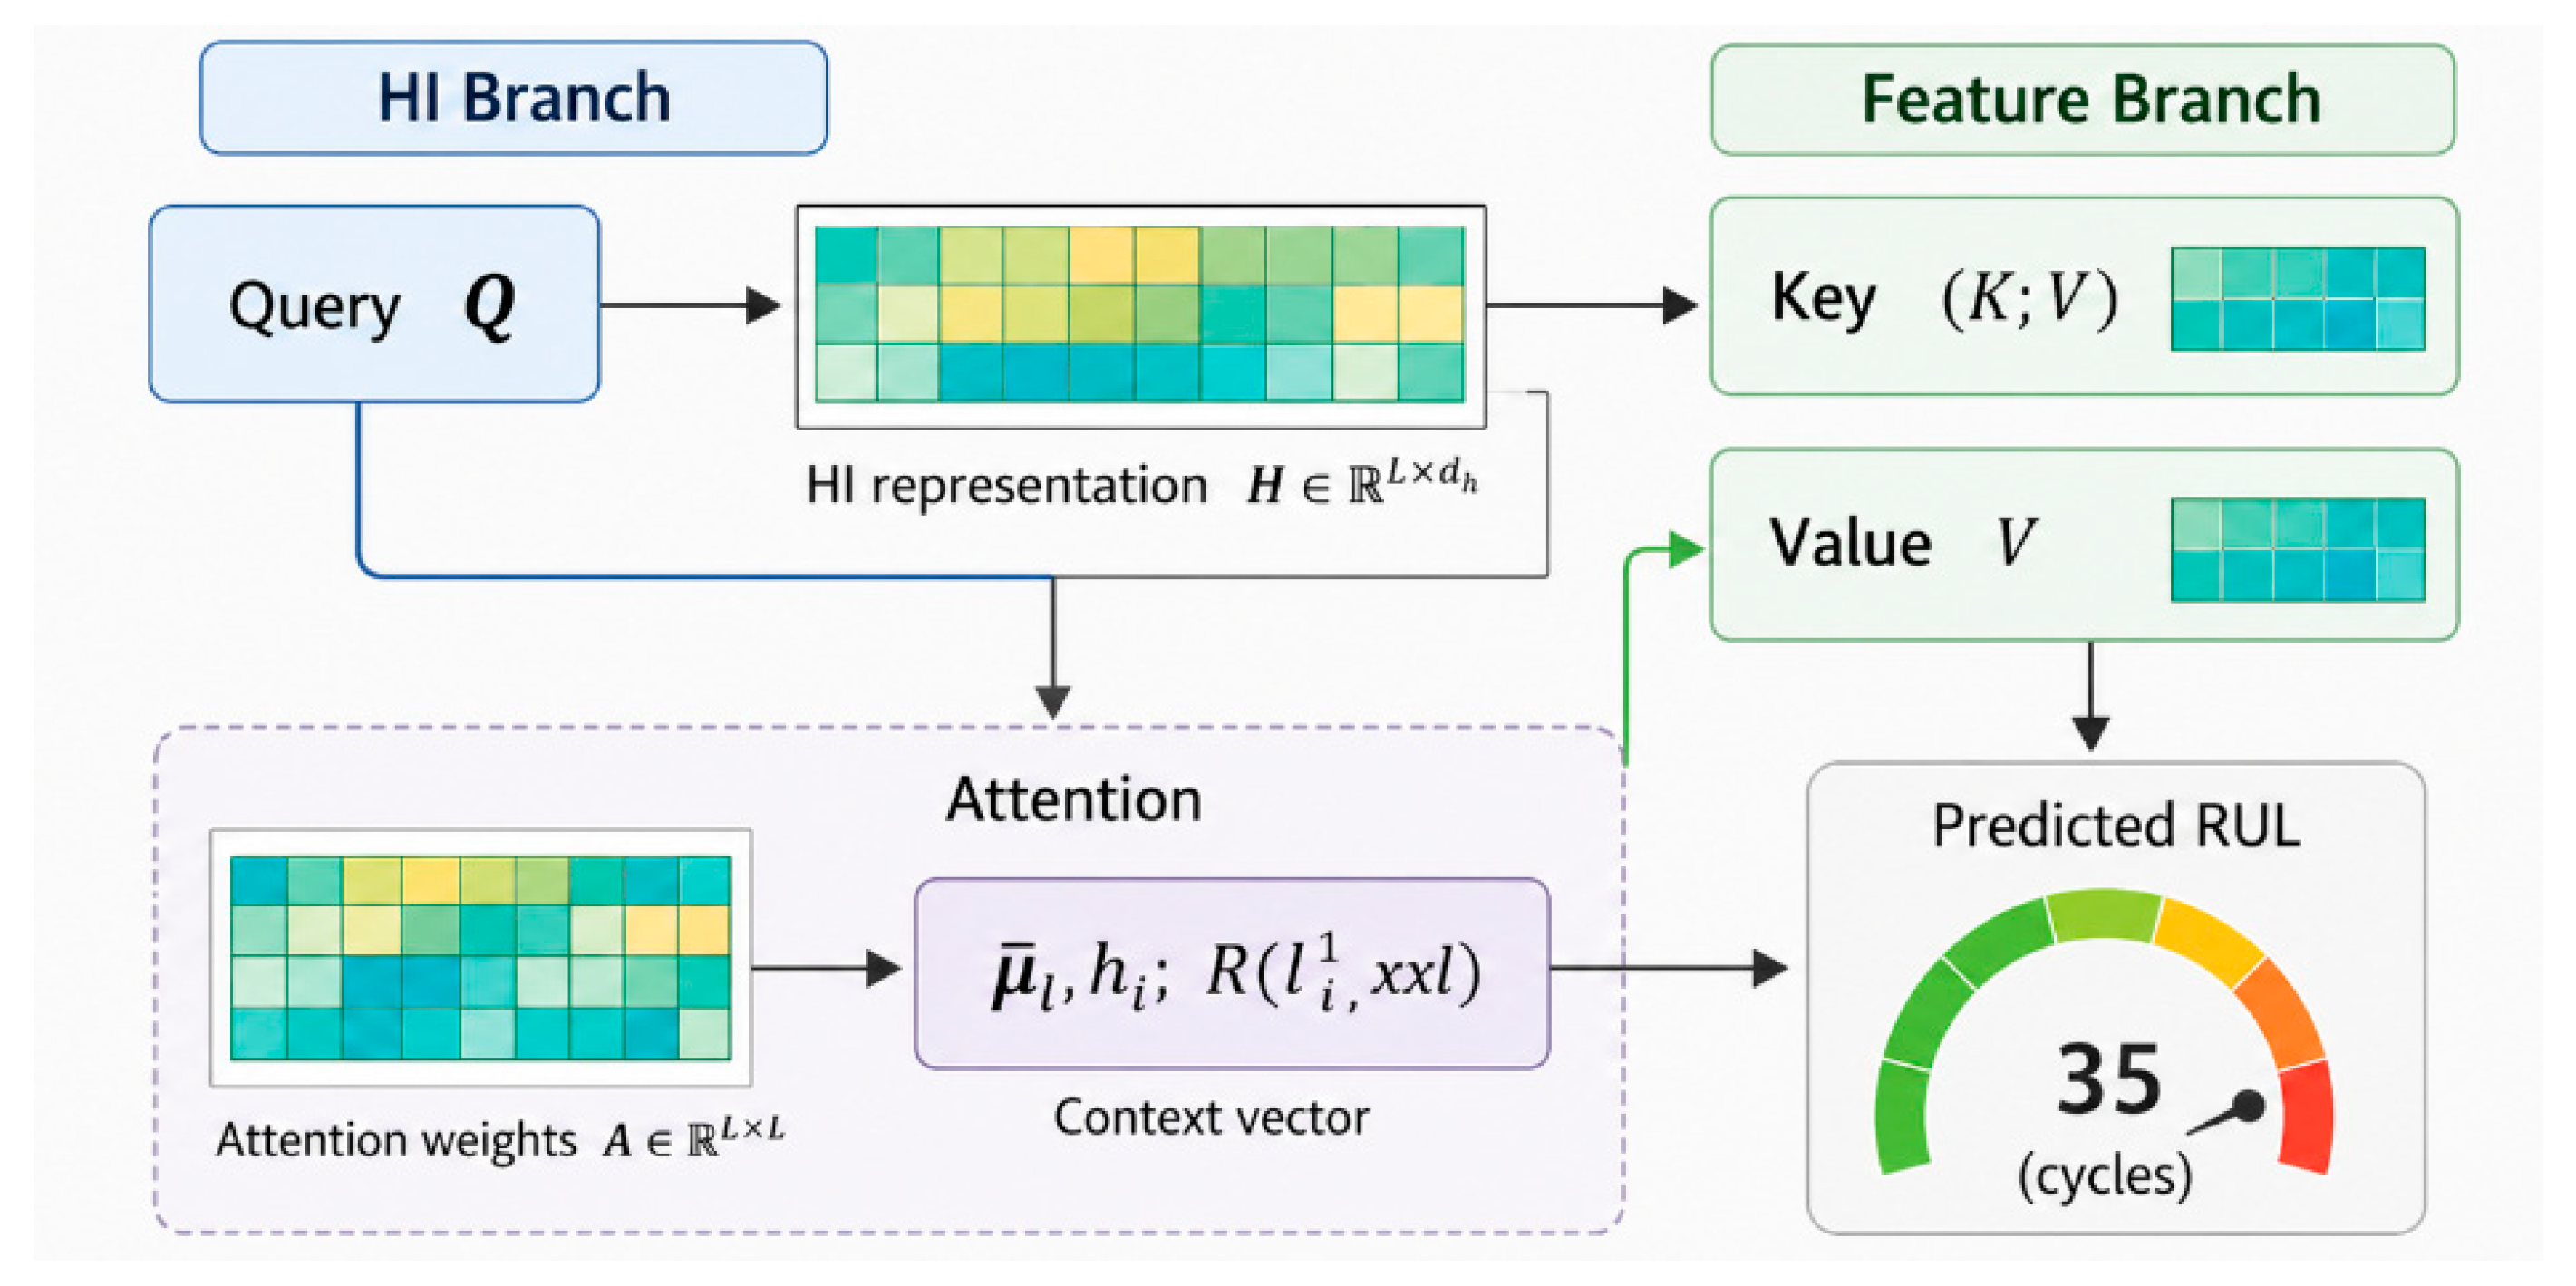
The resulting fused representation incorporates time-wise evidence from the feature stream while being guided by the HI stream. Intuitively, as the HI trajectory accelerates in latelife, the query vectors drive the model to assign higher weights to critical slices that contain strong fault signatures. The detailed HI-guided cross-attention fusion process was illustrated in Figure 4.
Figure 4.
HI-guided cross-attention fusion mechanism for RUL prediction.
Figure 4 illustrated the HI-guided cross-attention fusion mechanism. In this module, the HI branch provides query representations that encode the global degradation tendency, whereas the feature branch provides key and value representations that contain detailed vibration-related information. The attention operation adaptively assigns weights to different time steps within the input window. When the HI trajectory enters a transition or accelerated degradation stage, the model can allocate higher weights to more informative temporal fragments. Thus, Figure 4 explains how the proposed network combines interpretable HI dynamics with high-dimensional temporal features for RUL prediction.
Optionally, the symmetric fusion can be included by reversing the roles (feature-to-HI), and the two cross-attention outputs can be concatenated and projected. In this paper, the HI-to-feature fusion is used as the primary mechanism to maintain interpretability and limit model complexity.
2.5.4. Regression Head
The fused sequence representation is aggregated into a window-level embedding using attention pooling or a final-token selection:
The RUL prediction is obtained by a regression head:
where denotes a multilayer perceptron with nonlinear activation.
2.6. Training Objective
The model is trained by minimizing a regression loss between predicted and true RUL. To reflect the practical importance of late-life prediction, we introduce a stage-aware weighting scheme:
where is MAE or MSE and assigns larger weights to samples with smaller remaining life (e.g., ). This design encourages the network to reduce critical errors near failure. The hyper-parameters include the window length , stride , hidden dimension , number of encoder layers, number of attention heads, and dropout. Early stopping is used based on validation loss to prevent overfitting. All models and baselines are trained under identical data splits and evaluated using the same metrics to ensure fair comparison.
It should be noted that the present framework does not include an explicit domain-adaptation module. The cross-condition and cross-dataset experiments were designed to evaluate the inherent robustness and degradation-following generalization of the HI-guided temporal-attention framework, rather than to claim complete domain-invariant learning. Distribution shifts caused by sensor configuration, rotational speed, load, sampling system, and noise level are further analyzed in the Discussion section as important limitations and future research directions.
3. Results
3.1. HI Construction Effect Analysis
3.1.1. HI Trajectories and Degradation-Stage Correspondence
The constructed HI trajectories exhibited a stable-to-degrading evolution along the whole-life timeline. The HI values remained relatively flat in the early stage and then increased persistently as the bearings approached failure, which indicated that the fusion and degradation-consistency operations extracted progressive degradation information rather than transient disturbances. The accelerated rise of HI coincided with the growth of impulsiveness-related statistics and high-frequency band energy, suggesting that the HI captured both the onset and the intensification of defect-induced impacts. Condition-wise overlays further showed consistent stage patterns across multiple bearings, implying that the constructed HI reflected the shared degradation direction within each operating condition.
3.1.2. HI Quality Metrics Comparison
As reported in Table 2, quantitative HI assessment demonstrated that the degradation-consistency constraint improved HI reliability. After applying smoothing and quasi-monotonic operations, the monotonicity score increased, and the occurrence of non-physical reversals decreased. Meanwhile, trendability remained high across operating conditions, which suggested that the HI preserved the temporal degradation direction rather than being overly smoothed. The prognosability metric in the last-life segment also improved, indicating that the HI became more stable and discriminative near failure. These results confirmed that the constructed HI was suitable for providing a compact degradation trajectory for downstream RUL modelling.
Table 2.
HI quality metrics by condition.
3.1.3. Influence of Different HI Schemes on RUL Prediction
As shown in Table 3, the HI scheme study showed that RUL accuracy depended on the degradation consistency of the HI. When the monotonic HI was used, the overall errors decreased compared with raw or merely smoothed HI, indicating that suppressing non-physical oscillations improved temporal learning stability. Removing HI consistently degraded both overall and late-life performance, confirming that HI provided an informative low-dimensional trend cue that complemented high-dimensional temporal signatures. Therefore, the HI branch was not only an auxiliary input but also an effective degradation constraint for stabilizing RUL prediction across different life stages.
Table 3.
Impact of HI schemes on prediction performance.
3.2. RUL Prediction Performance Comparison
3.2.1. Overall Metric Comparison
To evaluate the effectiveness of the proposed framework against representative sequence-learning methods, several baselines were implemented under the same public-dataset protocol, including LSTM, CNN-LSTM, Transformer, and TCN-Transformer. All methods were trained and tested using the same bearing-level data split, sliding-window construction strategy, normalized RUL labels, and evaluation metrics. As summarized in Table 4, the proposed HI-guided temporal-attention model achieved the lowest overall RMSE and MAE on the test subset. Compared with LSTM and CNN-LSTM, the proposed method showed improved long-range temporal modelling and more stable degradation tracking. Compared with Transformer and TCN-Transformer, the proposed method further reduced prediction errors because the constructed HI provided a degradation-consistent trend constraint in addition to temporal attention. The comparison also showed that removing either the HI branch or the cross-attention mechanism degraded prediction performance, confirming the complementary roles of structured HI construction and temporal-attention modelling.
Table 4.
Overall performance comparison with representative sequence-learning methods.
3.2.2. Typical Bearing RUL Curves
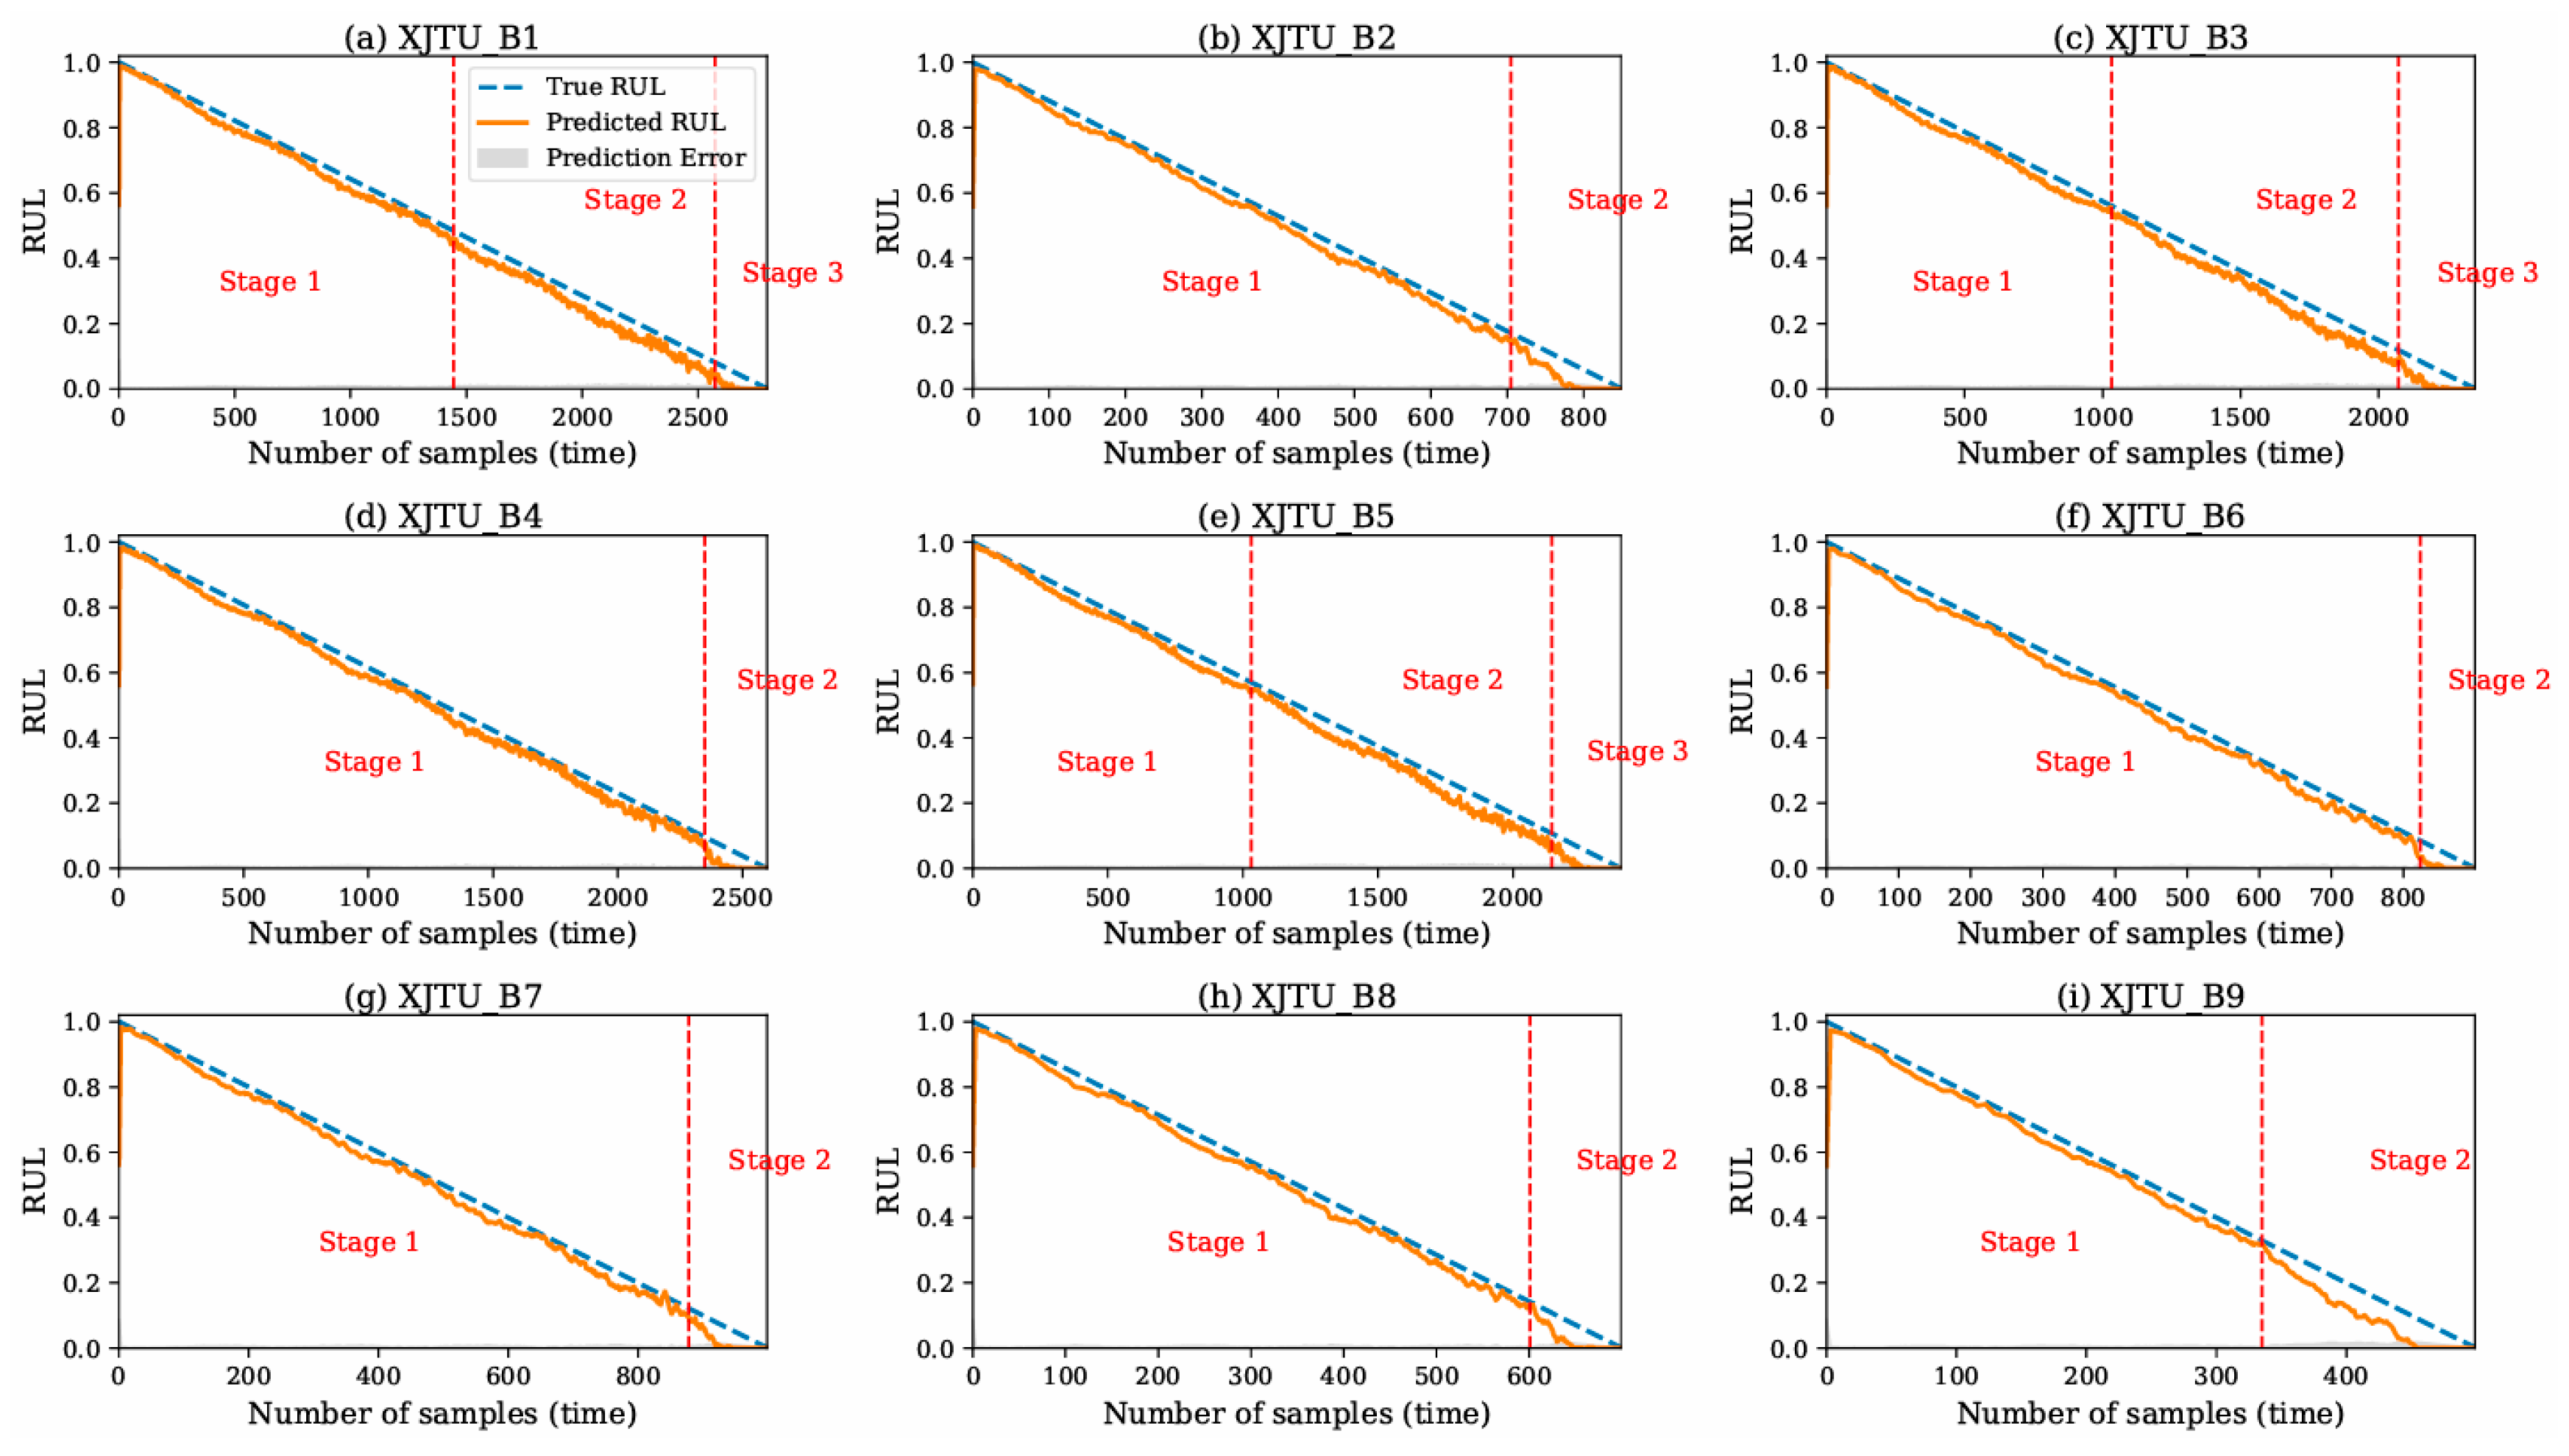
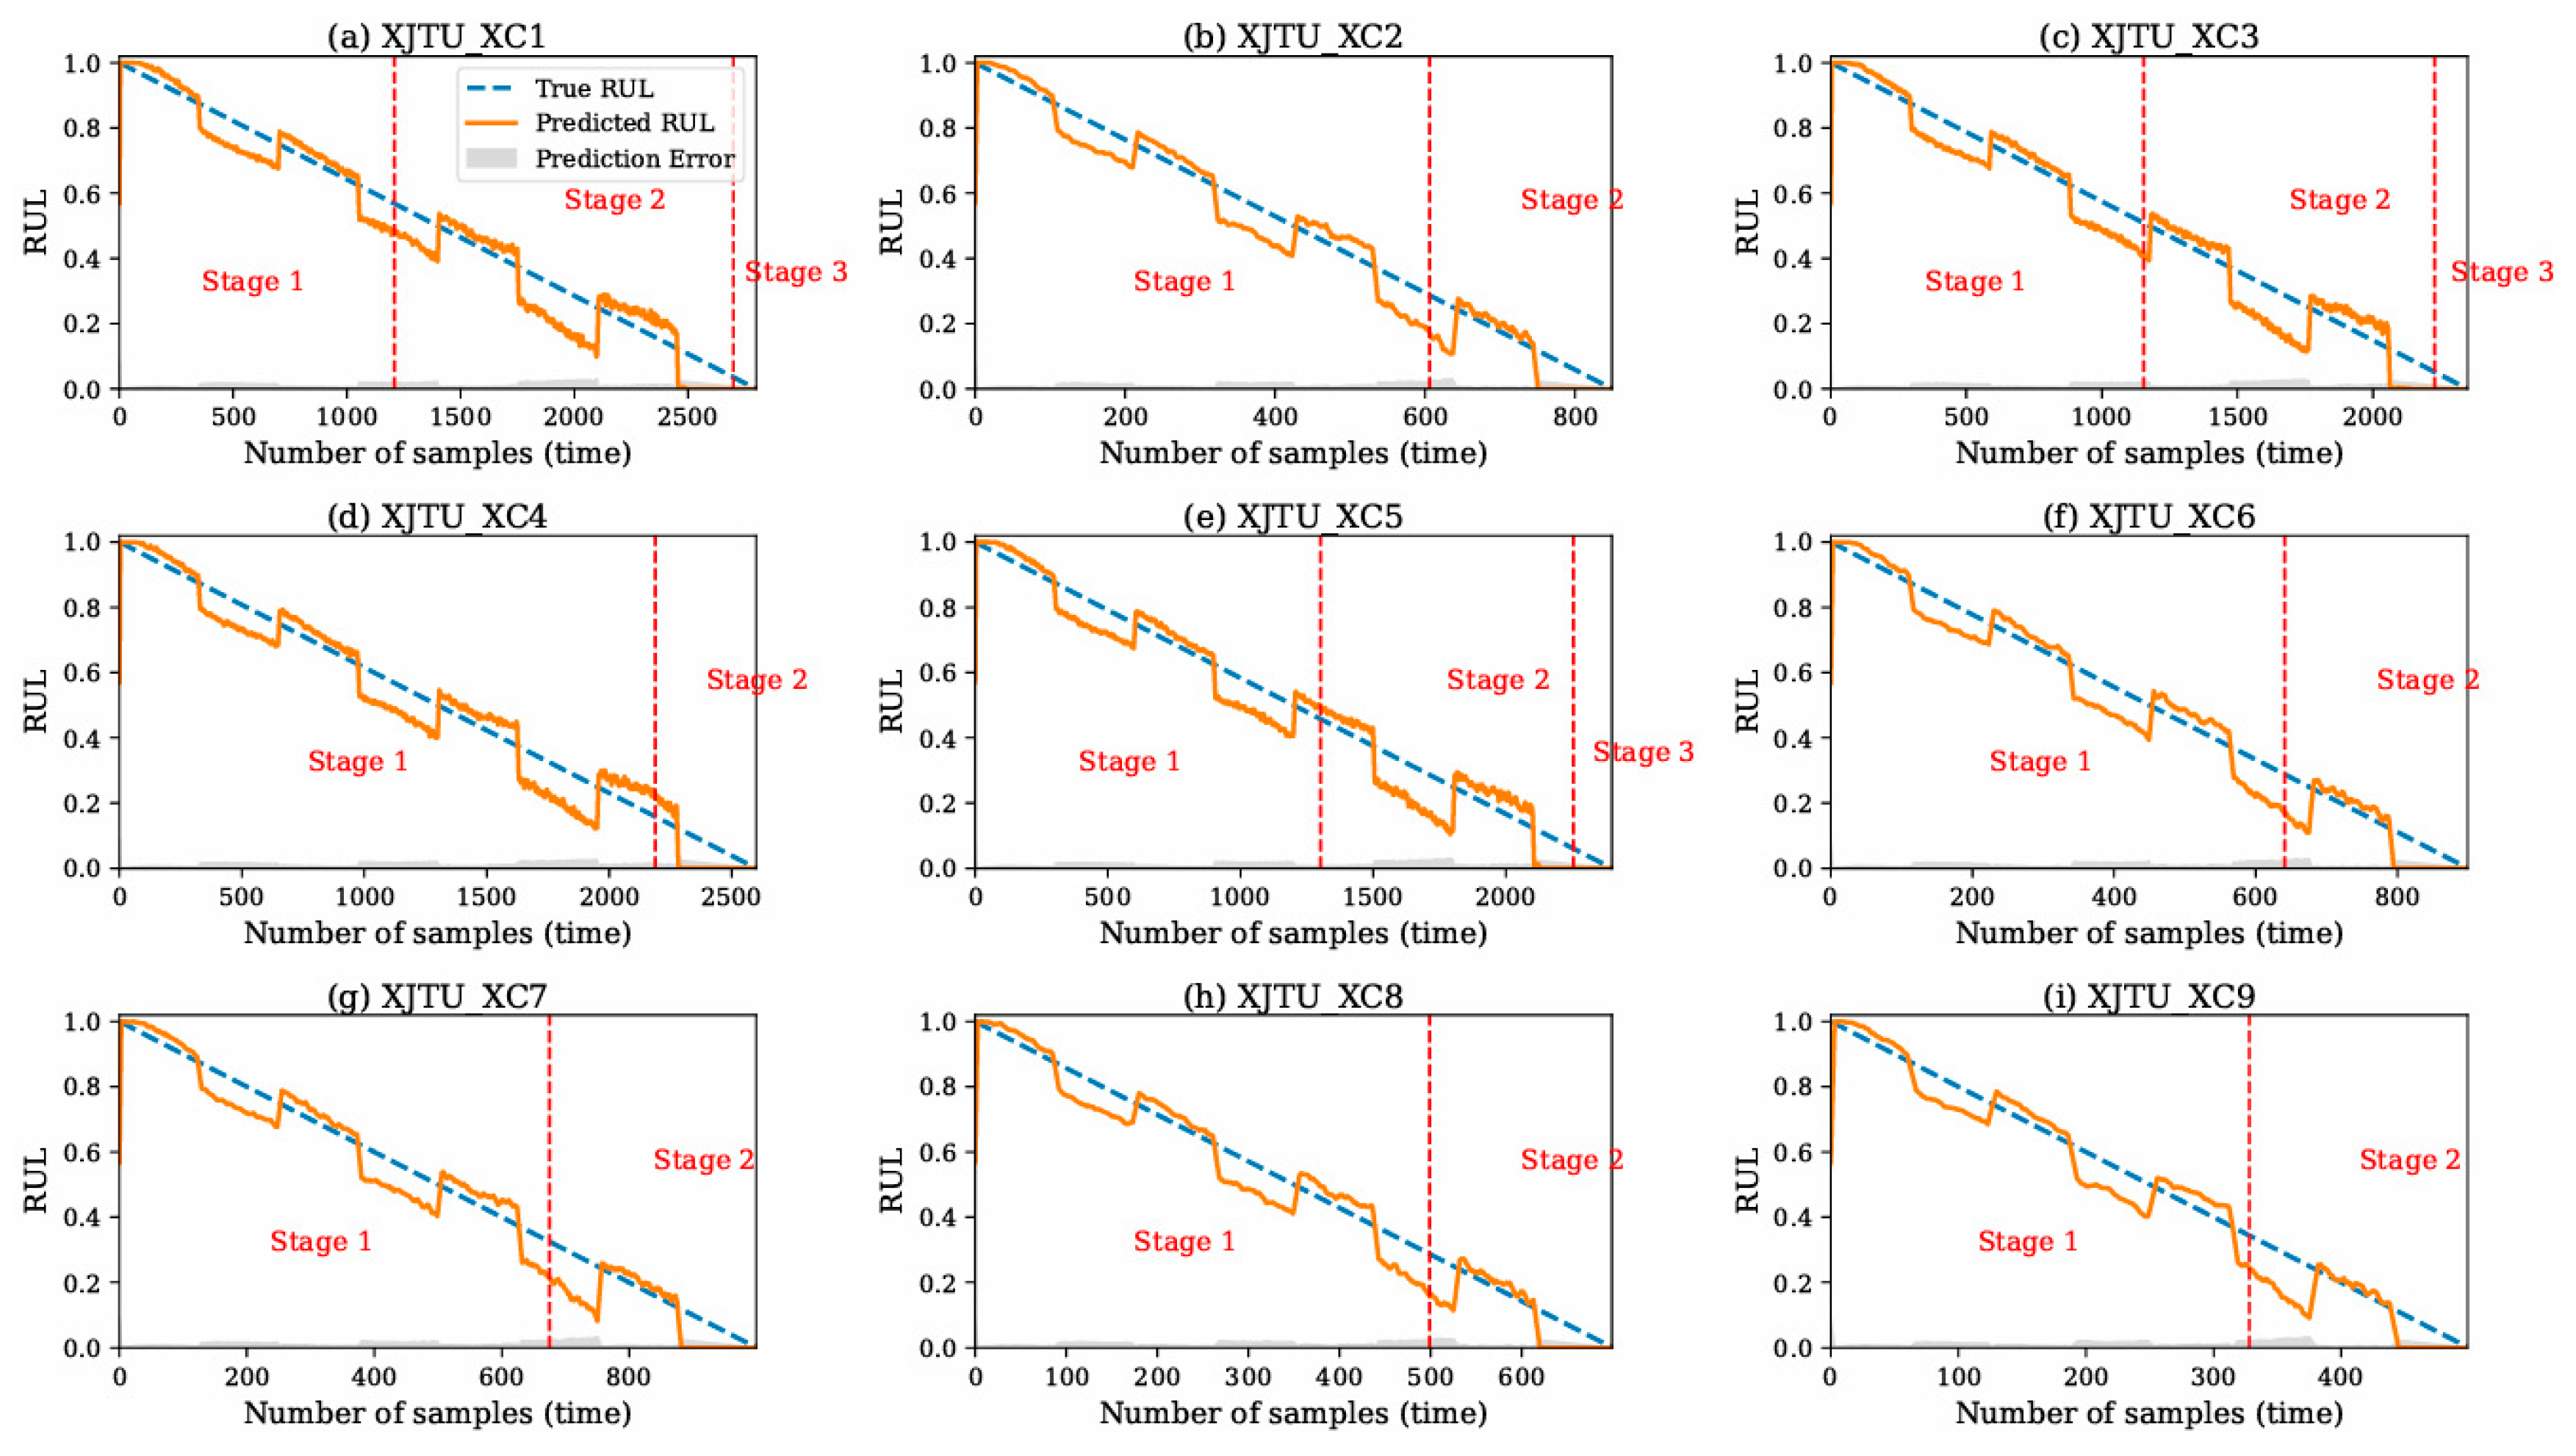
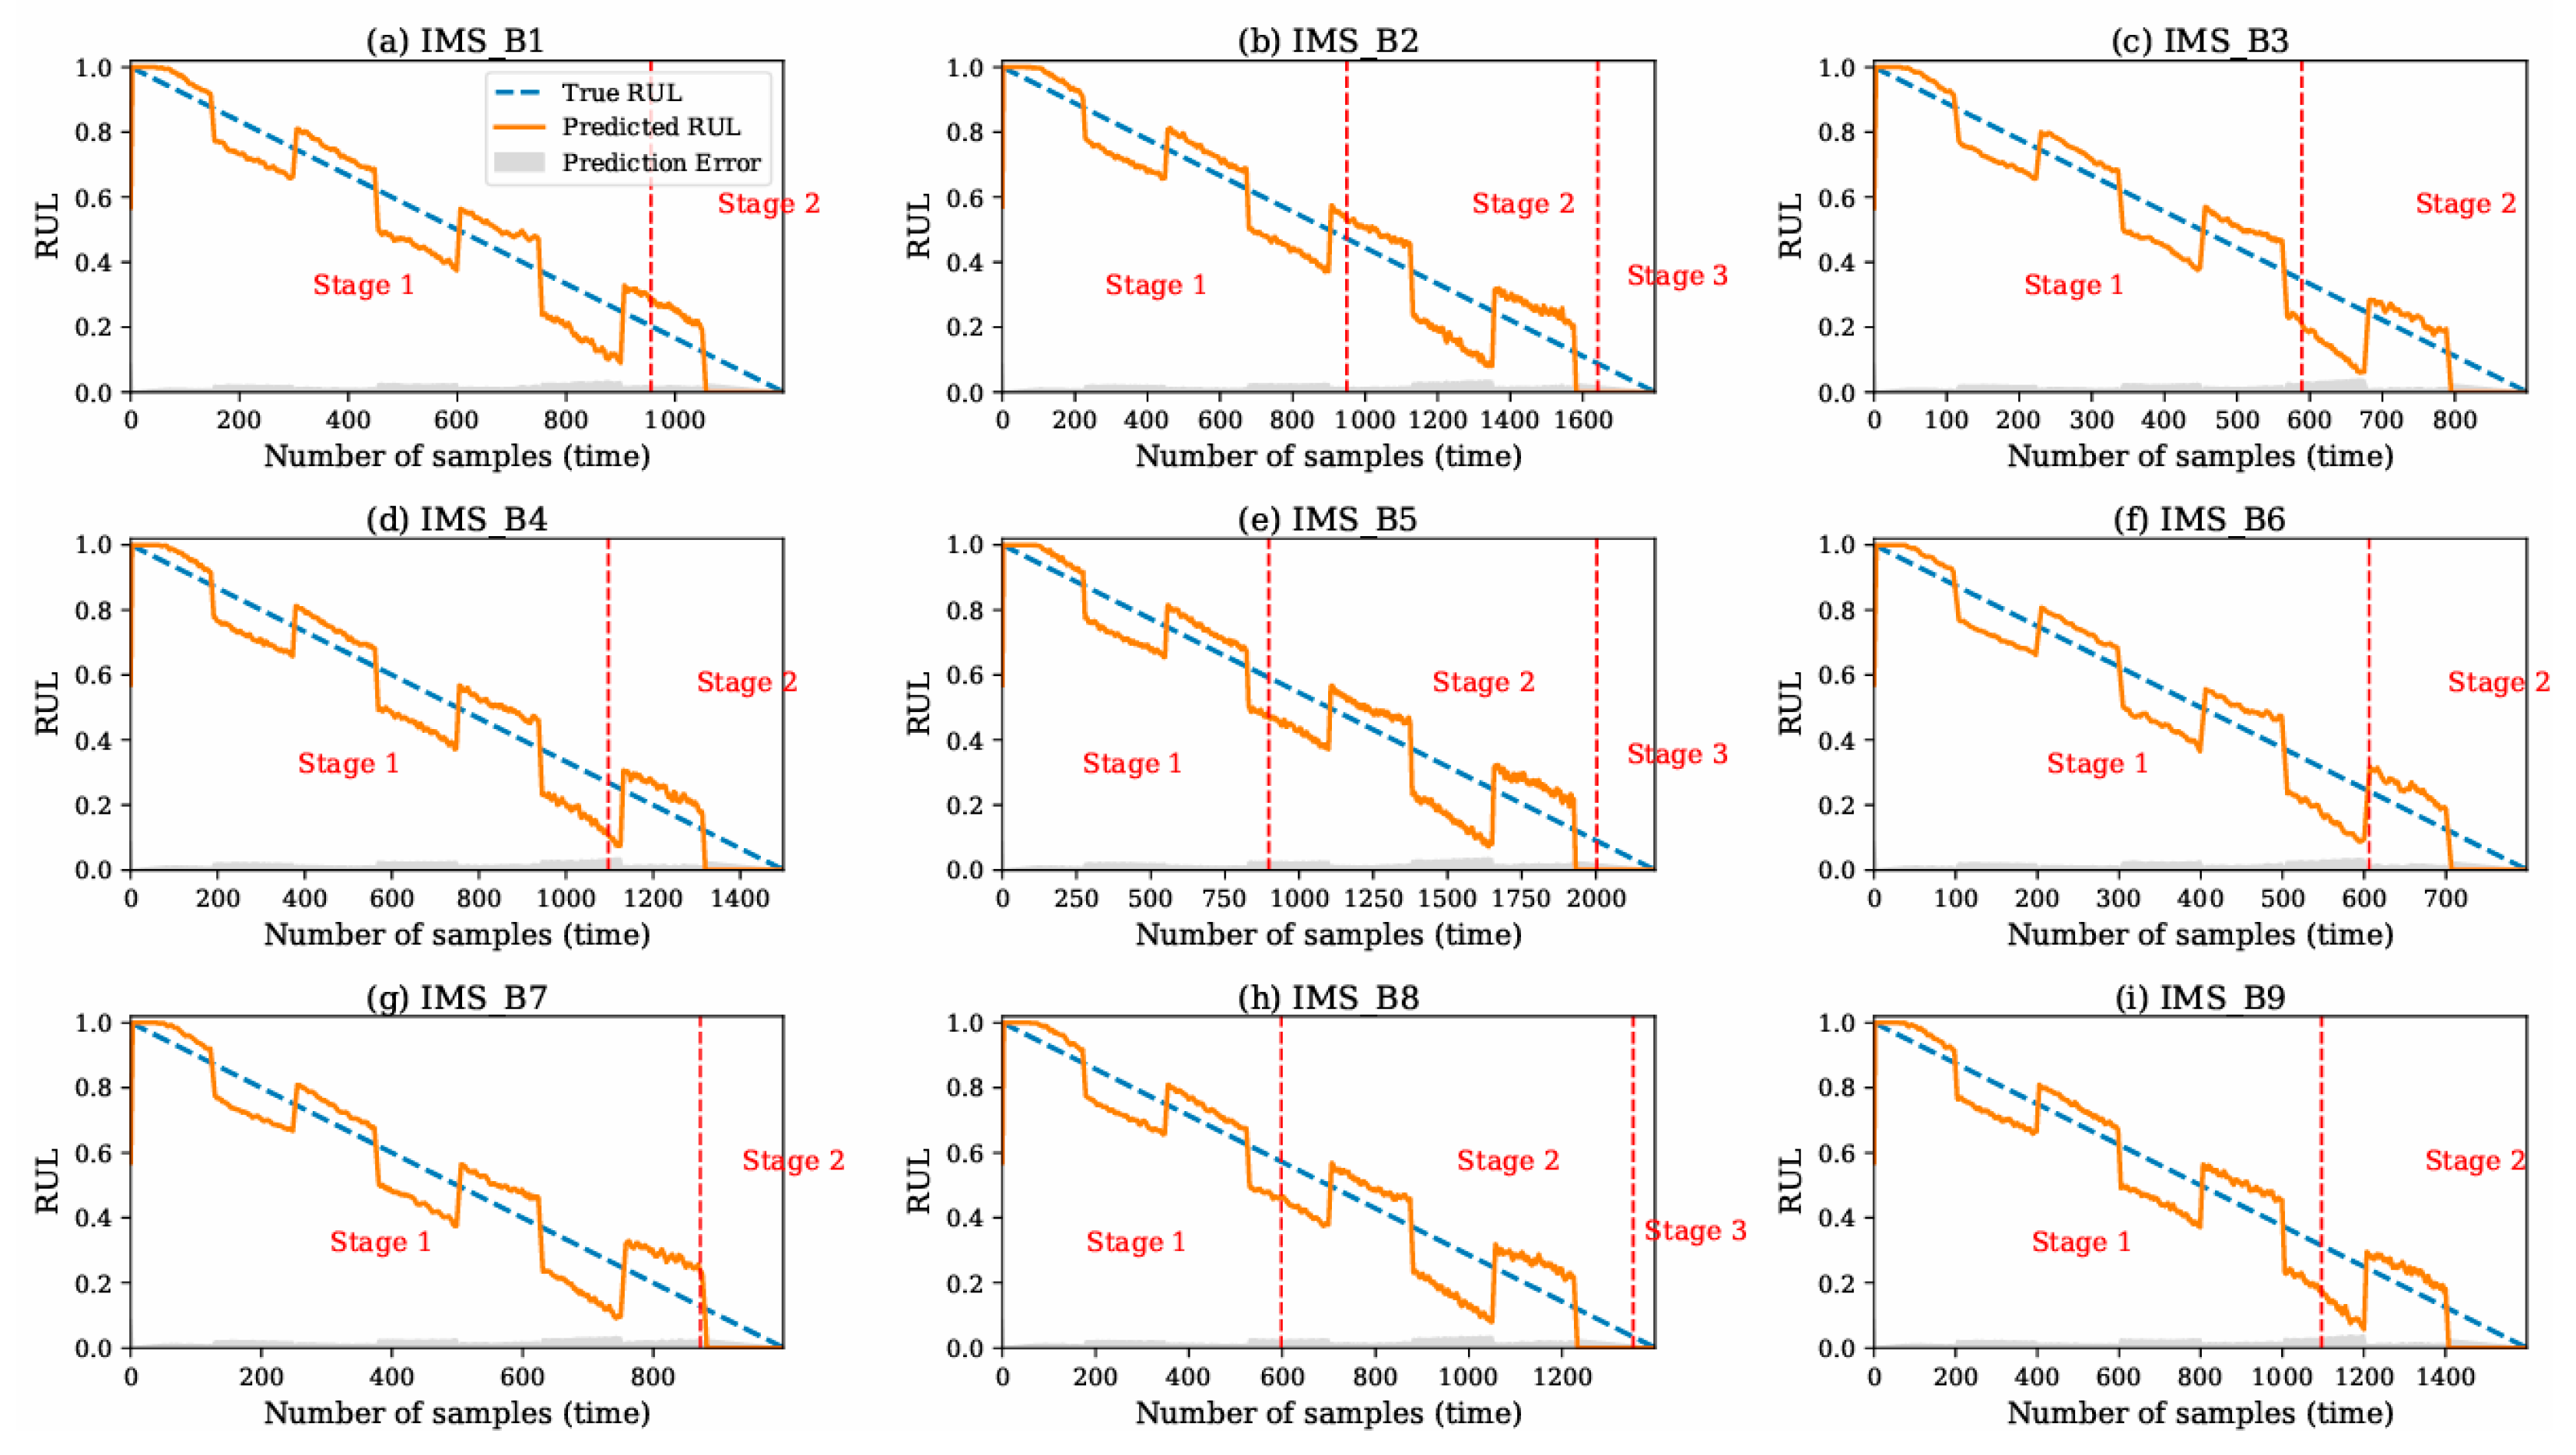
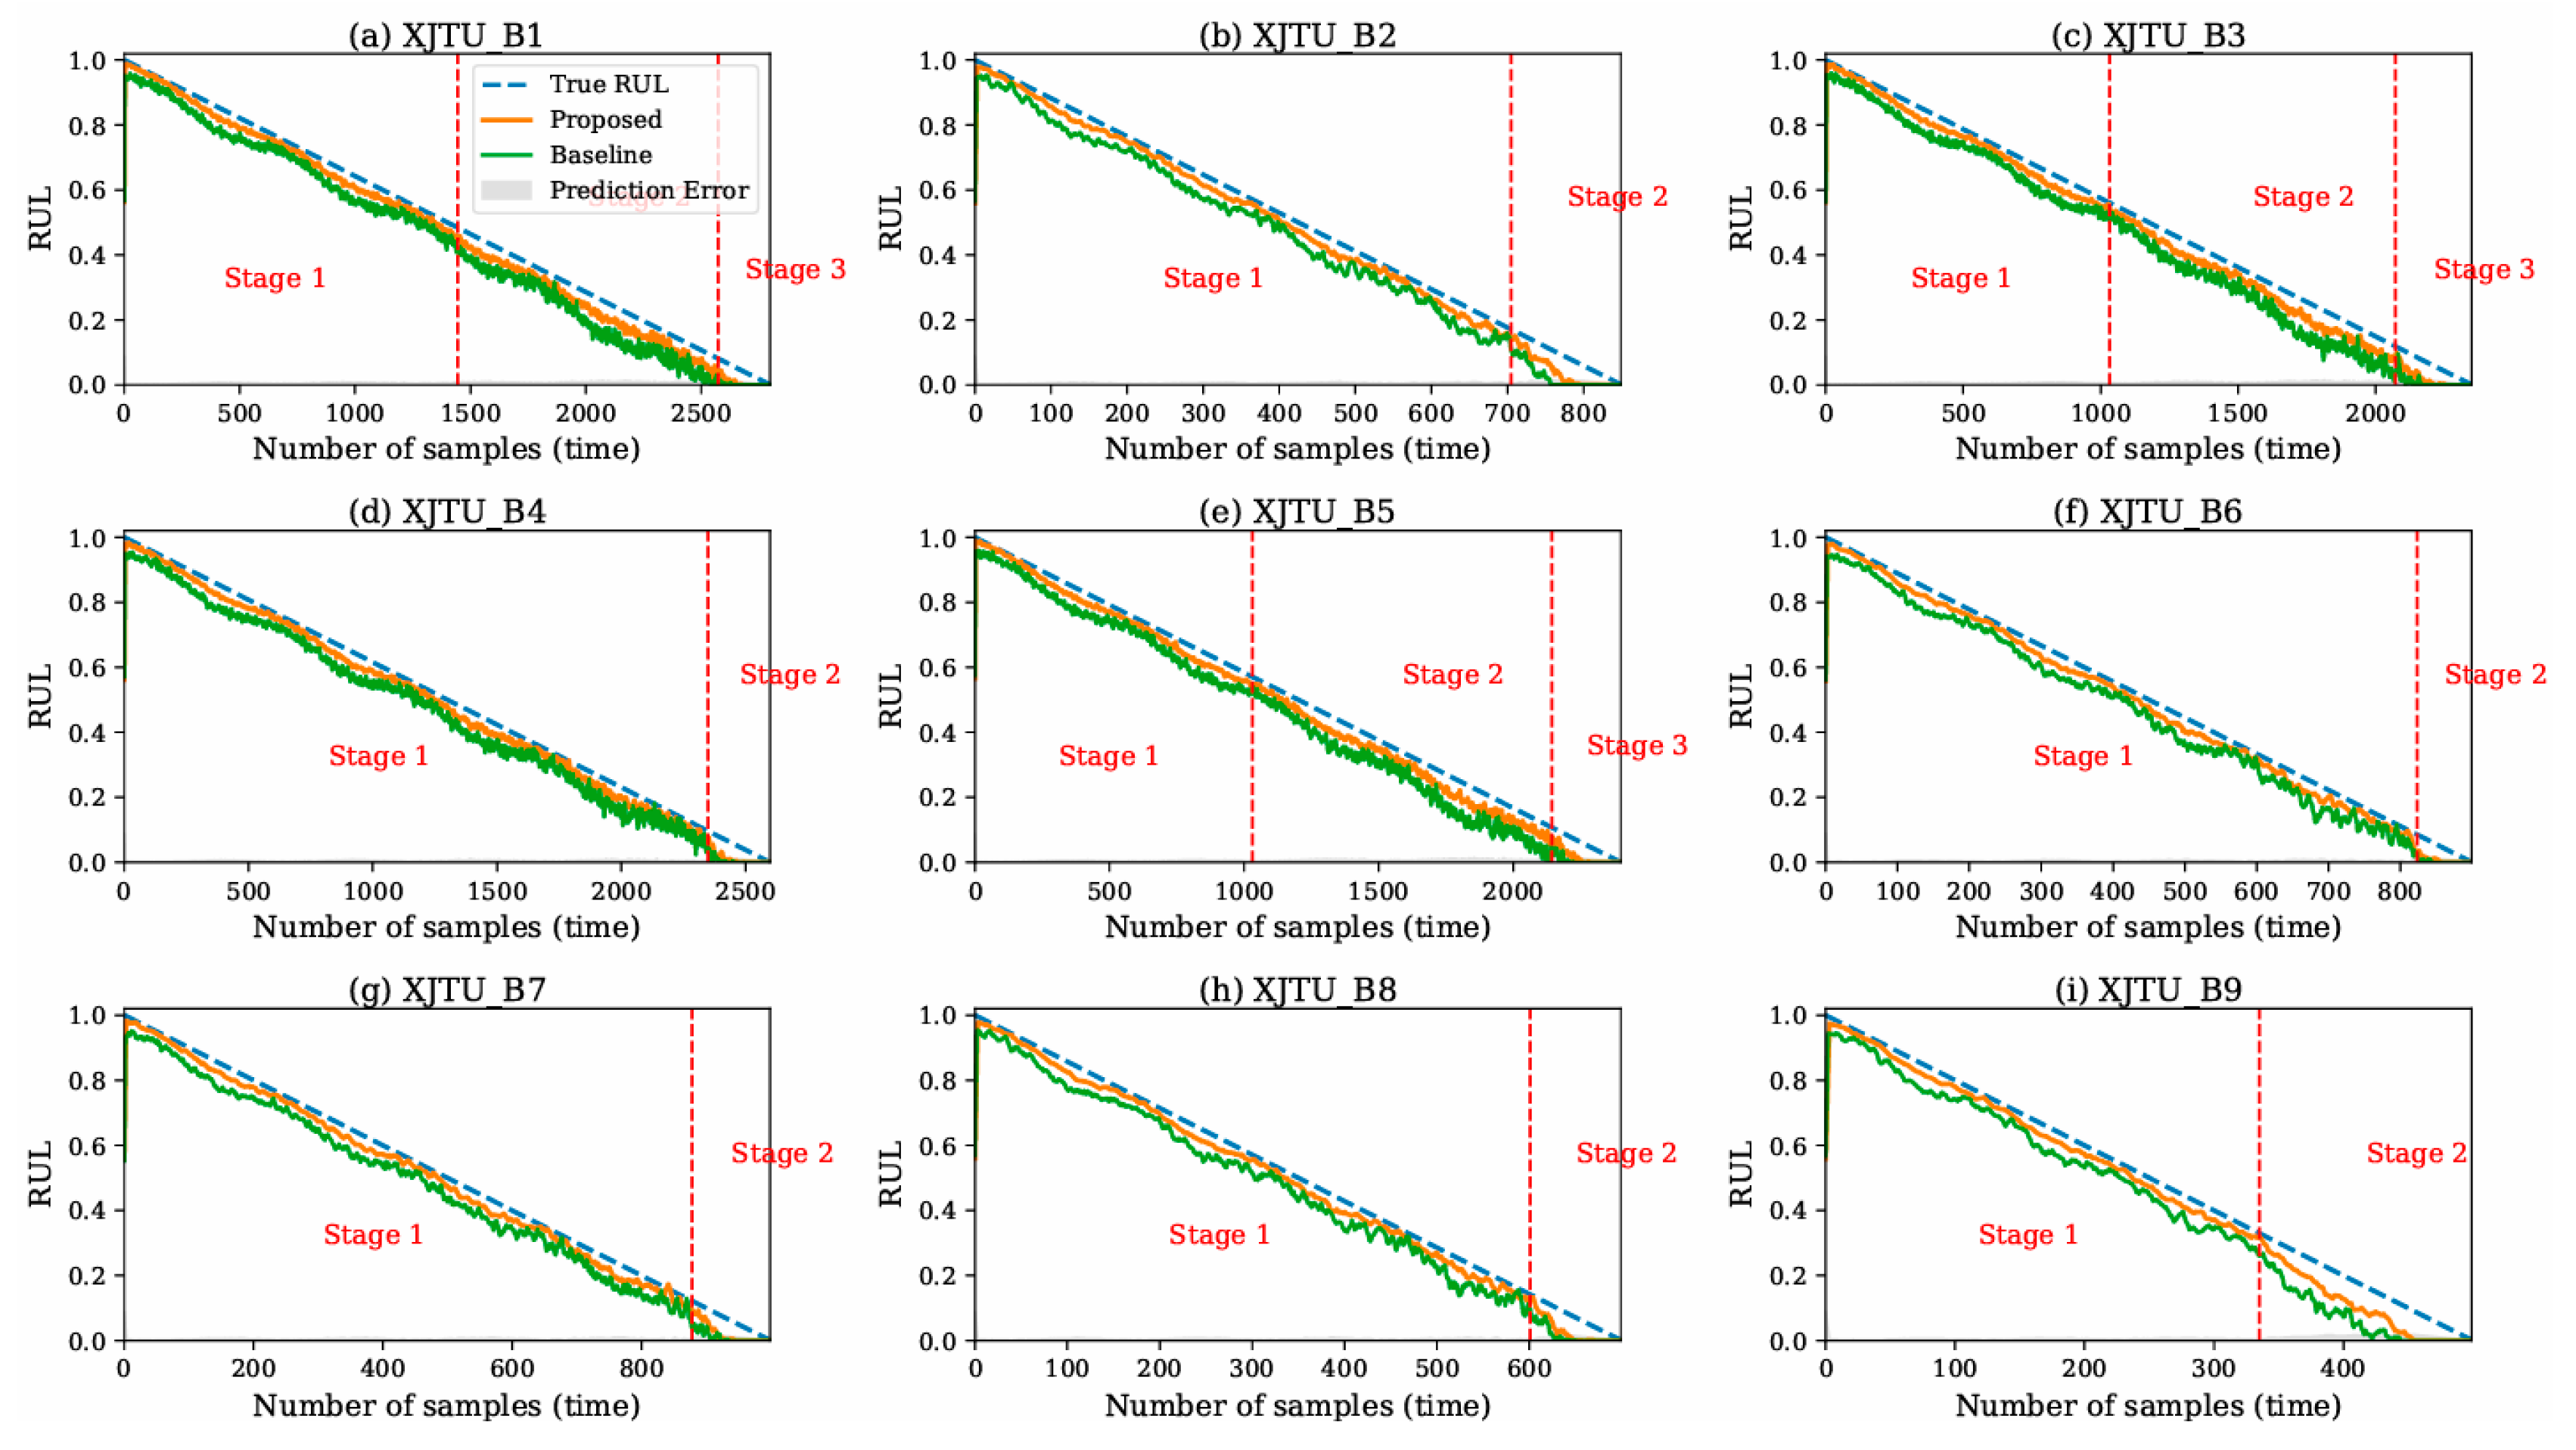
As shown in Figure 5, the case studies demonstrated that the predicted curves closely followed the decreasing trend of the ground-truth RUL across different XJTU-SY bearings. The proposed model reduced mid-life drift and produced smoother trajectories than the baseline, indicating that HI-guided fusion stabilized temporal encoding under gradual degradation. Figure 6 further reports representative bearings with discrete degradation-stage transitions. The staircase-like behaviour mainly originated from discrete run-to-failure acquisition and window-level RUL label assignment, where vibration slices within the same acquisition packet or window shared the same normalized RUL label before the label was updated in the next window. Therefore, the plotted ground truth and the corresponding predictions appeared as piecewise decreasing trajectories rather than fully continuous curves. This behaviour should not be interpreted as a physical square-wave degradation process; instead, it reflected the discrete sampling and label-generation protocol used for supervised RUL modelling. For bearings exhibiting abrupt degradation acceleration, the model still captured the main transition direction, although local deviations were observed near end-of-life, which was consistent with the challenge of impulsive and non-stationary signals prior to failure.
Figure 5.
Representative RUL prediction trajectories on XJTU-SY bearings.
Figure 6.
Representative RUL prediction trajectories with discrete degradation-stage transitions on XJTU-SY bearings.
3.2.3. Early-Stage Prediction Stability
As reported in Table 5, early-stage stability analysis showed that the proposed model maintained lower variability of prediction errors when the bearings were still in relatively healthy states. The reduced error standard deviation indicated that HI-guided fusion prevented the model from overreacting to early transient fluctuations. The early-stage bias remained close to zero, suggesting that the model did not introduce systematic overestimation or underestimation in the initial life segment. This stability was important for practical prognostics because unstable early-life predictions may lead to unnecessary maintenance decisions or premature alarms.
Table 5.
Early-stage prediction stability.
3.3. Early-to-LateStage Error Characteristics
As shown in Table 6, stage-wise evaluation revealed a clear difficulty escalation toward end-of-life. The MAE increased as true RUL decreased, indicating that late-life non-stationarity and impulsive events dominated the prediction uncertainty. The proposed model achieved more consistent improvements in the mid-life stages, suggesting that HI-guided cross-attention enhanced representation learning when degradation evolved gradually. In the final stage, the remaining errors suggested that additional robustness mechanisms or domain adaptation were required to further reduce failure-proximal uncertainty. This result also indicated that late-life prediction remained the most challenging part of bearing RUL modelling because fatigue-related local defects generated stronger and less stationary vibration responses near failure.
Table 6.
Stage-wise performance by true RUL bins.
3.4. Robustness and Generalization
3.4.1. Robustness Under Additive Noise Perturbations
Robustness experiments showed that the prediction error increased gradually as the noise level rose, which was consistent with the reduction of effective signal-to-noise ratio. However, the proposed method preserved a smooth degradation in performance rather than abrupt failure, indicating stable aggregation under perturbations. The late-life MAE was more sensitive to noise than the overall MAE, suggesting that failure-proximal segments relied heavily on impulsive cues that were more easily corrupted.
Additive Gaussian white noise was added to the original vibration signals to evaluate robustness under controlled perturbations. For a specified SNR level, the noise variance was determined according to the signal power, and the noisy signal was generated as , where follows a zero-mean Gaussian distribution. The clean condition and several noisy conditions were evaluated using the same trained model and the same testing protocol. The quantitative results are summarized in Table 7.
Table 7.
Robustness of the proposed method under additive Gaussian white noise.
3.4.2. Condition-Wise Performance Stability
Condition-wise analysis indicated that the proposed model maintained relatively stable performance across operating conditions. The error differences across conditions remained within a limited range, suggesting that the HI-guided fusion reduced reliance on condition-specific feature distributions. However, the observed variations also implied that operating-condition shifts still affected the learned degradation mapping.
Figure 5, Figure 6, Figure 7 and Figure 8 provided visual evidence for the quantitative results reported in Table 4, Table 5, Table 6, Table 7 and Table 8. Figure 5 evaluated whether the proposed method could follow the continuous degradation trend of representative XJTU-SY bearings. Figure 6 focused on bearings with discrete degradation-stage transitions and explained the staircase-like RUL behavior caused by discrete acquisition and window-level label assignment. Figure 7 examined cross-dataset prediction behavior on IMS bearing records, thereby supporting the generalization analysis. Figure 8 compared the proposed method with the baseline and the model without the HI branch across multiple bearings, visually confirming the stabilizing effect of HI-guided temporal modelling. These figures were included to complement the numerical metrics and to clarify how the proposed method behaved under different degradation trajectories and validation settings.
Figure 7.
Cross-dataset RUL prediction trajectories on IMS bearing records.
Figure 8.
Multi-bearing RUL prediction comparison among the proposed method, baseline, and model without the HI branch.
Table 8.
Cross-condition and cross-dataset prediction performance under variable operating conditions.
3.4.3. Performance Stability Under Variable Operating Conditions
The cross-condition evaluation was further analyzed to examine the stability of the proposed framework under variable operating conditions. As summarized in Table 8, prediction errors generally increased when the testing condition differed from the training condition. This degradation was mainly caused by changes in vibration amplitude, frequency distribution, degradation rate, and noise characteristics induced by different rotational speeds and loads. Although the proposed HI-guided temporal-attention framework maintained the degradation-following tendency, the error increase indicated that HI construction and temporal attention alone could not completely remove domain discrepancy.
4. Discussion
4.1. Consistency Between HI and Degradation Stages
The constructed health indicator (HI) exhibited a typical life-cycle evolution from an initially stable regime to a gradual degradation regime and finally an accelerated degradation regime. A noticeable change in slope and an increase in fluctuation magnitude were observed around the stage boundaries, indicating that the HI was sensitive to regime transitions while preserving the global degradation trend. From a mechanical perspective, the HI should not be interpreted as the physical cause of bearing degradation. Instead, it represented a compact data-driven description of vibration responses induced by progressive rolling-contact fatigue, local surface defects, and contact-interface changes. This interpretation was consistent with the fundamental bearing-failure mechanism in which repeated rolling contact gradually produced fatigue cracks, pitting, spalling, and local dynamic excitation.
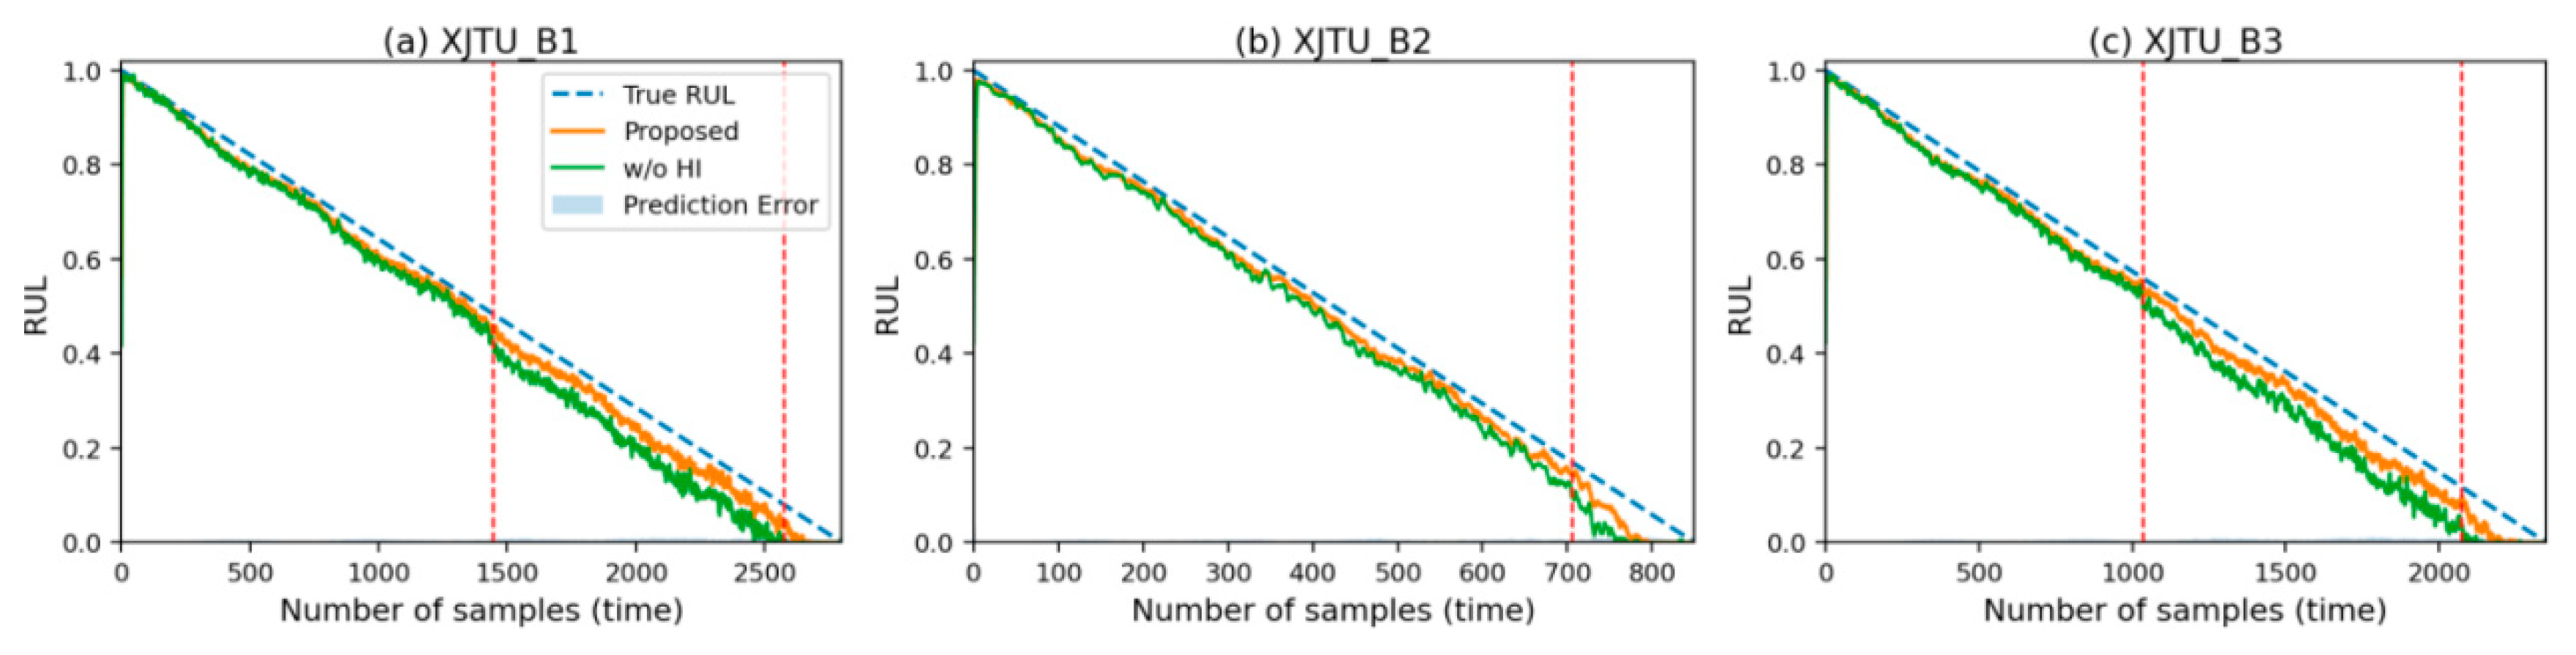
Moreover, the stage transition from Stage 2 to Stage 3 corresponded to a visibly more challenging prediction interval, which agreed with the engineering understanding that signal non-stationarity and impulsiveness increased as failure approached. These observations supported the use of HI as the front-end representation for RUL prediction, especially when the downstream model needed to capture stage-wise degradation dynamics. The corresponding prediction-error trajectories used to support the ablation interpretation are presented in Figure 9.
Figure 9.
Prediction error trajectories of representative XJTU-SY bearings.
As shown by the prediction error trajectories in Figure 9, the ablation study showed that removing HI led to larger systematic deviations and amplified fluctuations in the predicted RUL trajectories, particularly in Stage 2 and Stage 3. The uncertainty band expanded more rapidly near the late-life region, indicating that the model without HI relied more heavily on local pattern fitting and became more susceptible to noise and transient disturbances. This result implied that HI played two complementary roles in the proposed framework. First, HI aggregated multi-dimensional vibration features into a smoother degradation coordinate, effectively suppressing irrelevant high-frequency variations and reducing the sensitivity of temporal modelling to transient noise. Second, HI constrained the learning process to follow a consistent degradation direction over long horizons, which mitigated cross-stage drift and reduced premature pessimistic or overly optimistic extrapolation near failure. Consequently, the HI-based design yielded a more stable error profile and improved robustness in the most critical late-life segment.
4.2. Contribution of Temporal Attention to Cross-Stage Modeling and Interpretability
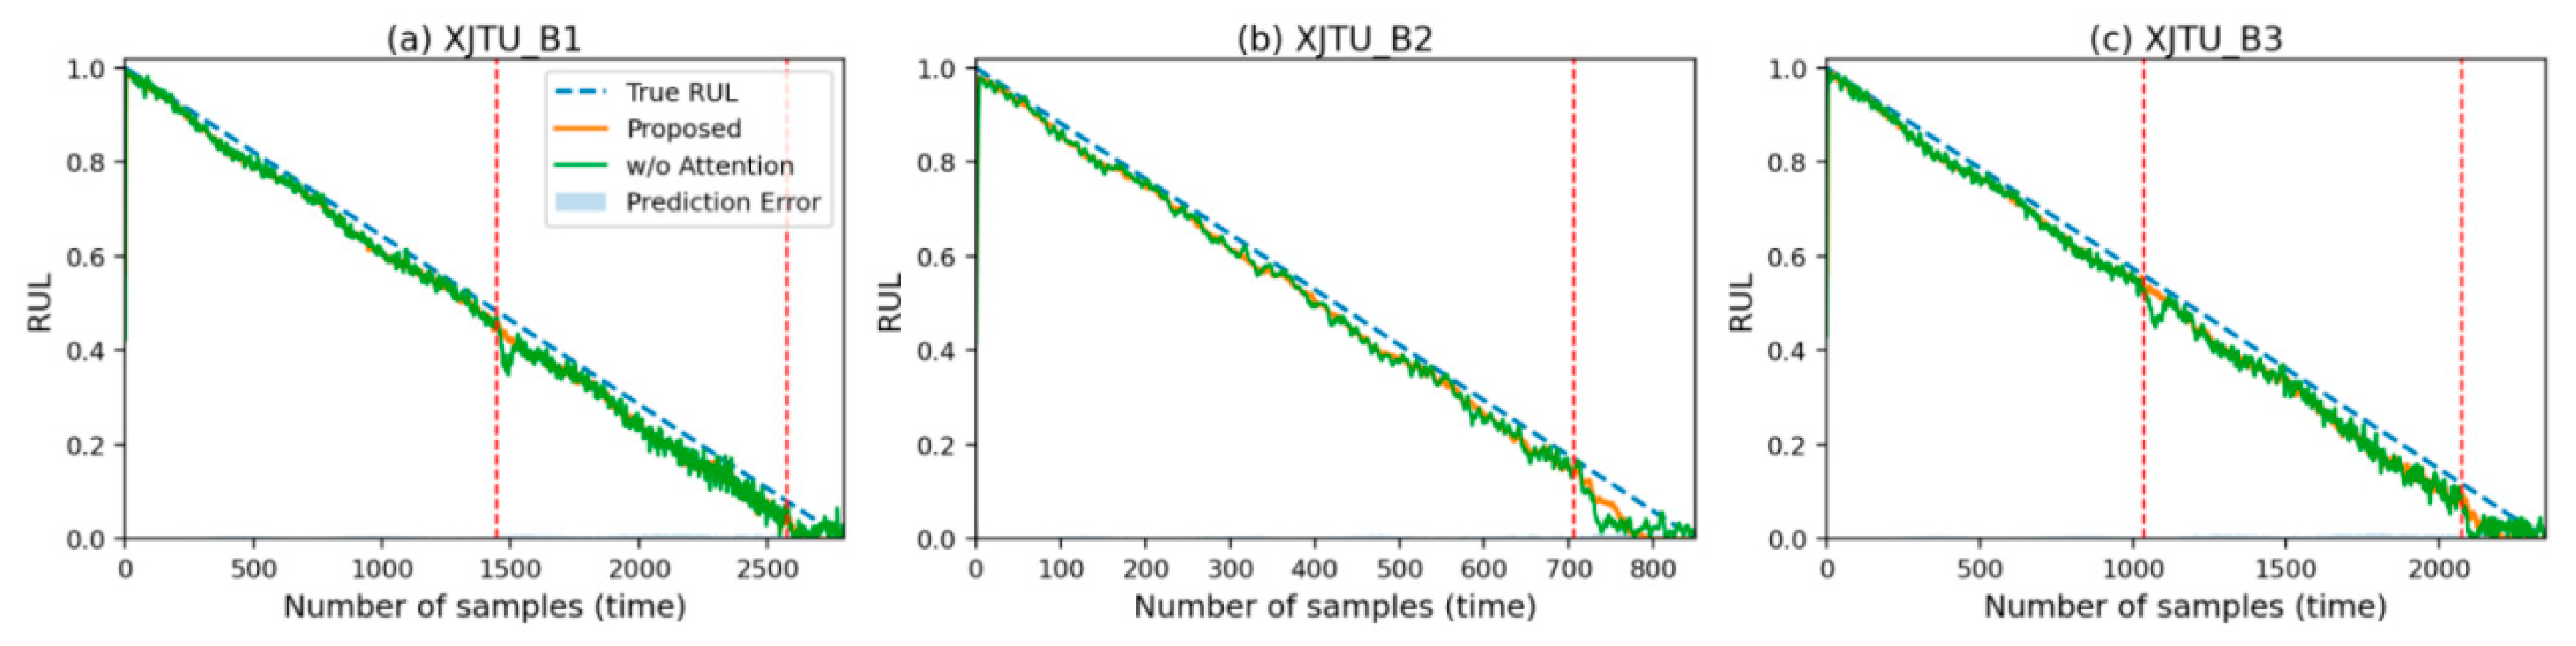
Introducing temporal attention enhanced the model’s ability to allocate different importance weights to historical segments, thereby improving its capability to capture stage transitions and accelerated degradation patterns. As illustrated in Figure 10, the model with temporal attention produced more stable RUL trajectories than the variant without the attention-guided fusion mechanism. The attention ablation results indicated that removing the attention module increased prediction errors around the Stage 2-to-Stage 3 transition and enlarged late-life deviations.
Figure 10.
Influence of temporal attention on representative RUL prediction trajectories.
The contribution of temporal attention was mainly reflected in two aspects. On the one hand, it enabled selective focusing on informative degradation fragments rather than uniformly averaging over many weakly informative windows. On the other hand, it compensated for long-range dependency modelling, allowing the network to remain responsive to key changes even under long sliding windows. The attention weight visualization further indicated that the model assigned higher weights to samples near stage boundaries and late-life regions. This behavior provided qualitative evidence that the network leveraged structured degradation cues instead of fitting only local noise, thereby improving both prediction performance and interpretability.
It should also be noted that temporal attention did not replace the physical interpretation of degradation. Instead, it provided a data-driven mechanism to identify which historical vibration segments were more informative for RUL regression. When combined with the HI branch, the attention module allowed the model to use the degradation trend as guidance and to emphasize feature segments that were more closely related to fatigue-induced dynamic changes. This design explained why the proposed model showed stronger stability during transition and late-life stages than the feature-only and attention-free variants.
4.3. Late-Life Performance and Hard-Case Analysis
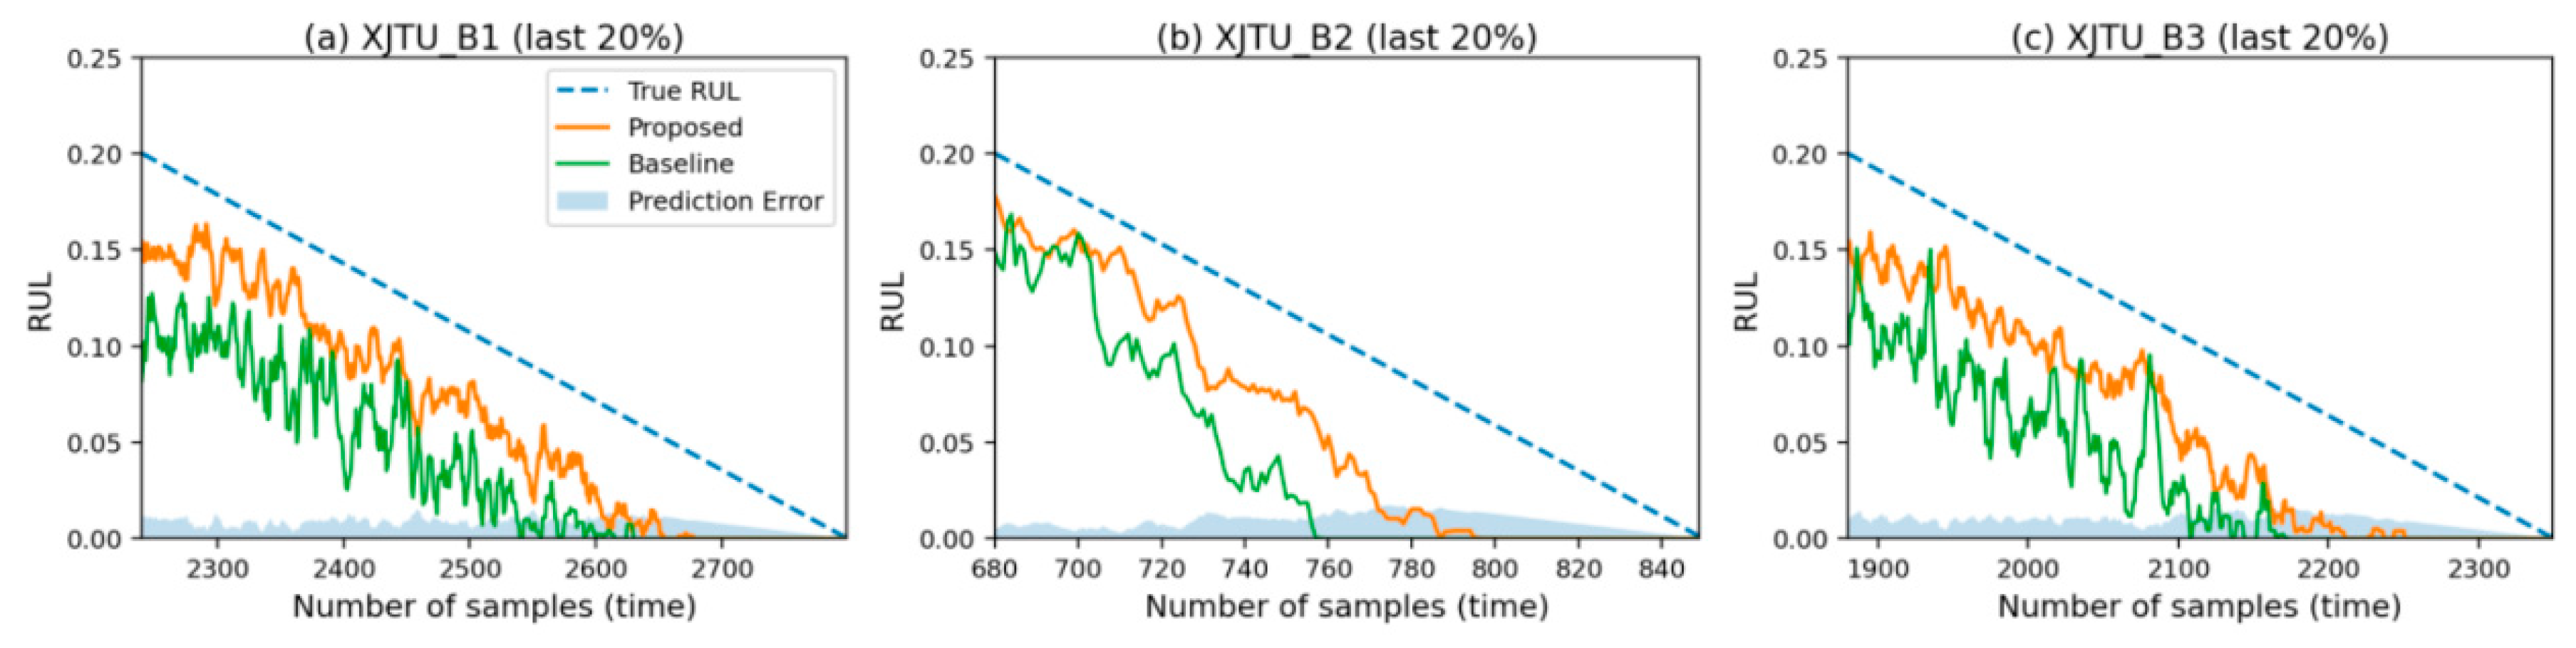
The last-life segment close to failure was generally considered the most difficult regime for RUL prediction because of strengthened non-stationarity, more frequent impulsive components, and more pronounced distribution shift. As shown in Figure 11, the zoom-in evaluation on the final portion of the lifetime demonstrated that the proposed method maintained good trajectory agreement with the ground truth and exhibited a smaller error expansion than the baseline.
Figure 11.
Late-life zoom-in RUL prediction results in the last 20% life stage.
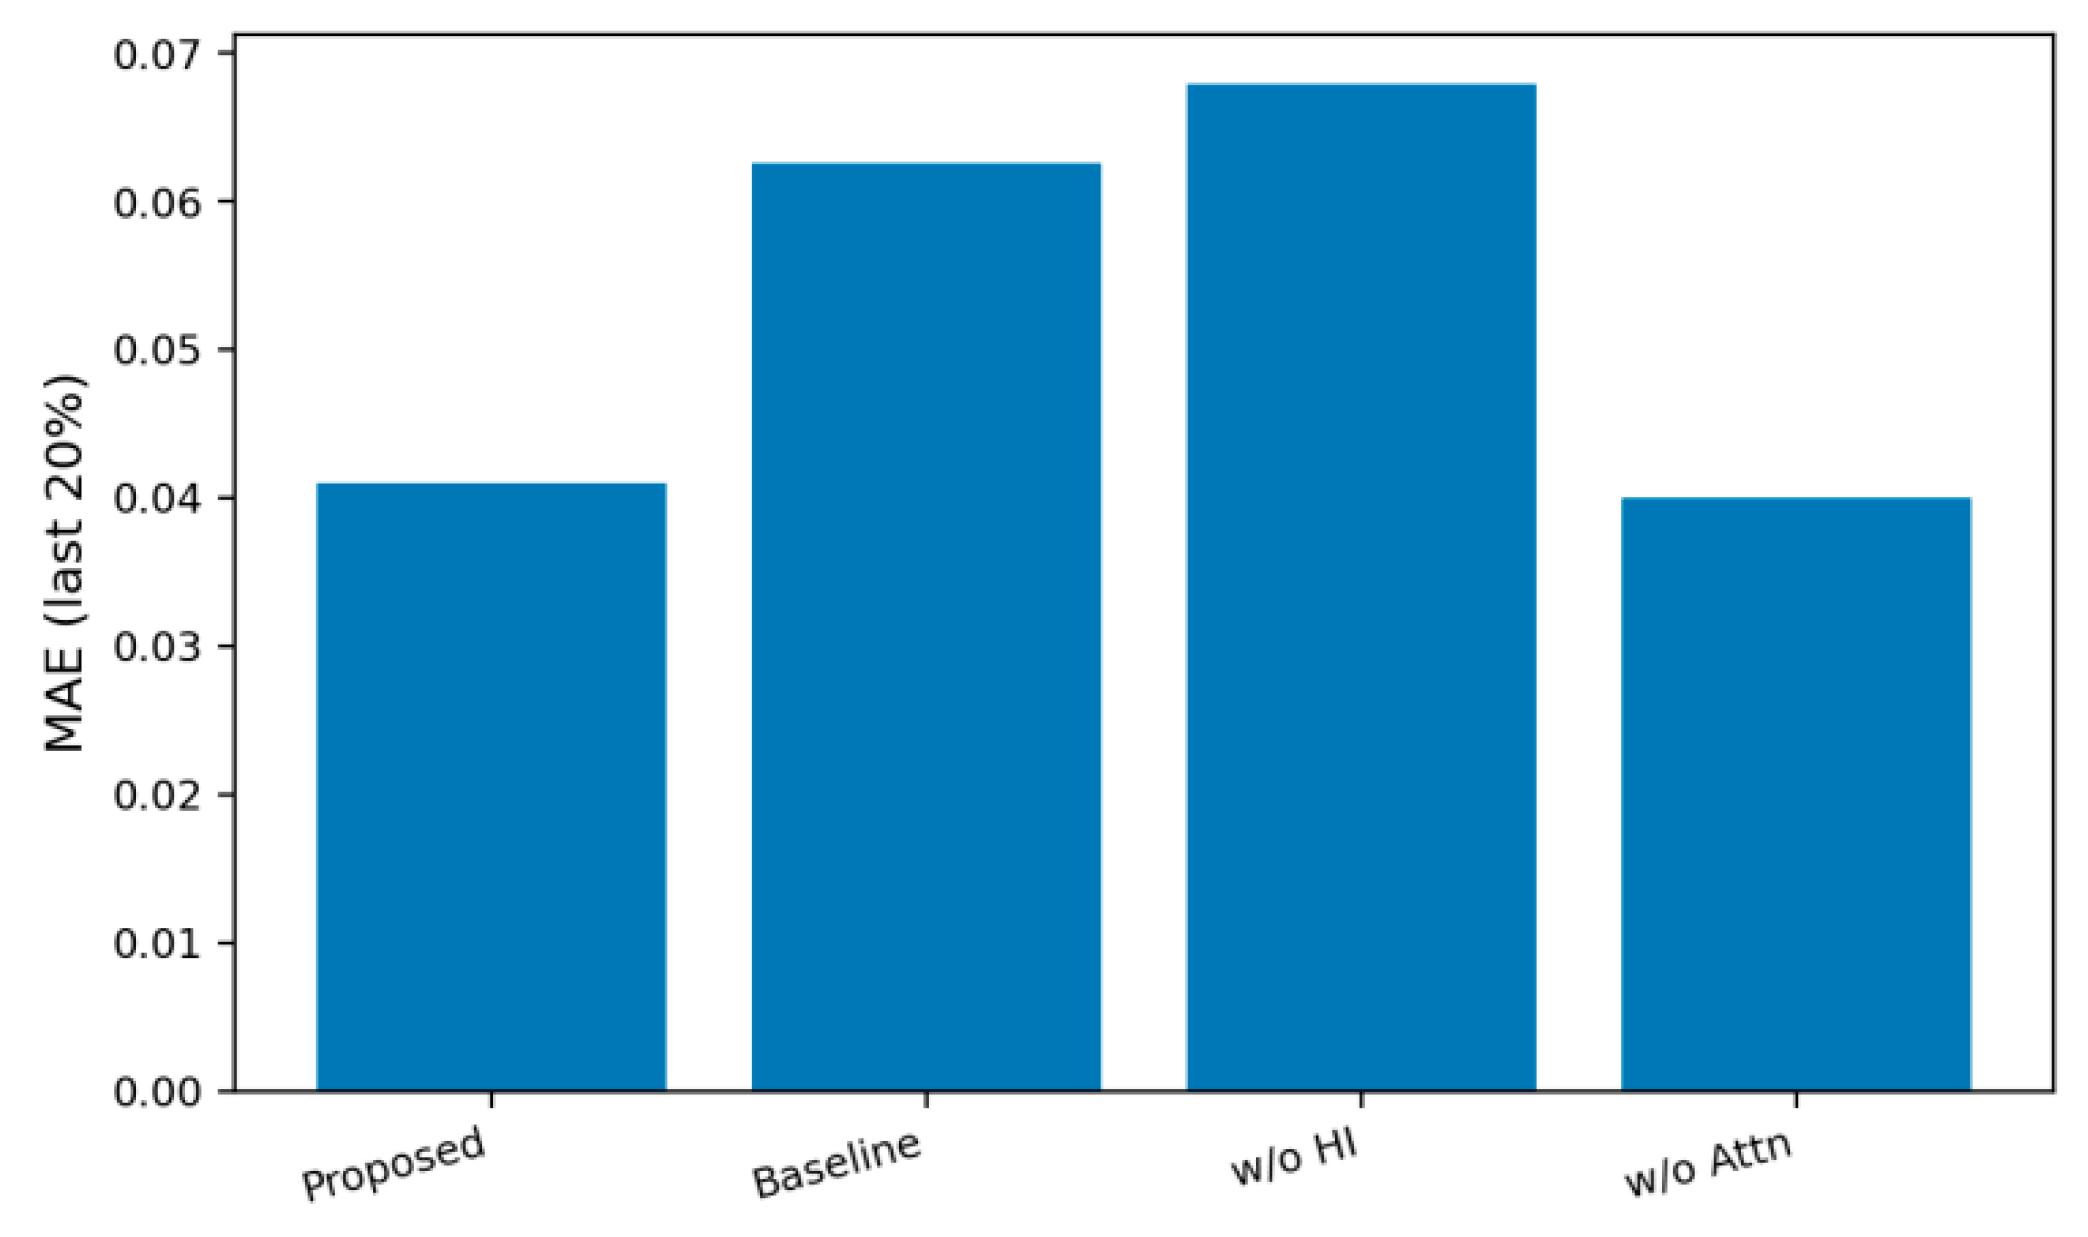
The late-life MAE comparison in Figure 12 further confirmed the advantage of the proposed framework over the compared variants. The lower late-life MAE suggested that the HI-based trend constraint and the attention-based key-fragment selection jointly reduced overfitting risk and improved adaptation to accelerated degradation.
Figure 12.
Comparison of late-life MAE among model variants.
The remaining prediction errors were concentrated mainly around the overlap of regime transition and late-life acceleration. This pattern indicated that the final-life stage still dominated the uncertainty of RUL prediction. Mechanically, this uncertainty was reasonable because local fatigue defects could develop rapidly near failure, producing stronger impacts, more irregular vibration modulation, and less stationary feature distributions. From an application perspective, the observed late-life stability supported the practical value of the proposed framework for safety-critical maintenance decisions. However, further improvements could still be obtained by integrating adaptive windowing, transition-aware loss reweighting, explicit change-point constraints, or fatigue-informed feature construction.
4.4. Generalization Across Operating Conditions and Datasets
Cross-condition and cross-dataset validation showed that the proposed framework retained acceptable degradation-following behaviour, but prediction errors increased compared with in-domain testing. This phenomenon was consistent with the practical difficulty of bearing prognostics under variable operating conditions. When rotational speed, radial load, sensor position, sampling system, or noise level changed, the vibration signal distribution shifted in terms of amplitude scale, frequency composition, impulsiveness, and degradation rate. Such shifts affected both the constructed HI trajectory and the learned temporal mapping from historical degradation segments to RUL labels.
The proposed HI-guided temporal-attention framework partly mitigated these effects by compressing multi-dimensional vibration descriptors into a smoother degradation-oriented HI and by allowing the attention mechanism to focus on informative historical fragments. However, the method did not explicitly enforce domain-invariant feature learning. Therefore, the cross-domain results should be interpreted as evidence of improved robustness and degradation-following stability, rather than as a complete solution to domain adaptation. In practical deployment, preprocessing alignment, sensor calibration, operating-condition identification, and lightweight target-domain fine-tuning were still necessary when the target environment differed substantially from the source training domain.
The vibration responses used for RUL prediction were also interpreted in relation to their mechanical sources. Bearing-induced vibration could originate from local fatigue defects, raceway or rolling-element waviness, contact-stiffness variation, clearance, lubrication-state variation, misalignment, imbalance, and spindle–bearing assembly dynamics. As bearing fatigue developed, these sources generated impulse-like responses and modulated vibration components, which were captured by accelerometers and transformed into degradation features. This interpretation was consistent with the view that vibration monitoring provided observable evidence of evolving contact fatigue rather than acting as the physical cause of degradation.
Consequently, the proposed HI was regarded as a data-driven representation of fatigue-related dynamic responses. However, because these vibration responses were influenced by sensor position, rotational speed, radial load, lubrication state, acquisition noise, and test-rig configuration, cross-condition and cross-dataset prediction still suffered from distribution shift. Future work should therefore combine fatigue-informed feature construction, vibration-source attribution, and formal domain-adaptation mechanisms to improve physical interpretability and industrial transferability. Potential extensions included transfer learning with limited target-domain samples, adversarial domain alignment, maximum mean discrepancy-based feature distribution matching, and domain-invariant HI construction. In addition, entropy-based descriptors, especially dispersion entropy and its multiscale variants, could be incorporated into the HI construction stage to better characterize nonlinear and non-stationary vibration fluctuations under variable operating conditions.
5. Conclusions
This study proposed a health-indicator-guided temporal-attention framework for rolling bearing remaining useful life prediction. The method first transformed multi-dimensional vibration features into a degradation-consistent health indicator (HI), which was used to represent fatigue-related vibration responses rather than the physical cause of bearing degradation itself. The HI sequence was then integrated with feature sequences through a temporal cross-attention mechanism to improve stage-aware RUL modelling. In this framework, the HI branch provided degradation-trend guidance, while the feature branch supplied detailed vibration evidence induced by progressive rolling-contact deterioration.
Experimental results showed that the constructed HI exhibited clear life-cycle evolution and stronger degradation consistency than raw or merely smoothed variants. The proposed prediction model achieved the best overall performance among the compared settings. In particular, the HI-guided cross-attention design reduced overall RMSE and MAE, improved early-stage prediction stability, and limited error amplification in the late degradation stage. These results indicated that the combined use of structured degradation representation and temporal attention was effective for improving both prediction accuracy and robustness.
Further analysis demonstrated that the proposed framework was especially advantageous in stage-transition regions and near-failure intervals, where bearing vibration responses typically became more impulsive, non-stationary, and difficult to model. The ablation results confirmed that HI construction provided a compact and interpretable degradation trajectory that mitigated cross-stage drift, whereas temporal attention improved the model’s ability to focus on informative historical fragments and capture long-range temporal dependencies. In addition, robustness and cross-domain evaluations suggested that the method preserved relatively stable degradation-following behaviour under additive noise, varying operating conditions, and cross-dataset settings. These findings supported its practical value for condition-based maintenance and safety-critical prognostics.
Nevertheless, several limitations remained. The identification of degradation onset and stage boundaries could still be uncertain under different datasets and operating conditions. HI construction could be sensitive to feature selection and parameter settings under stronger noise, more complex failure mechanisms, or abrupt degradation transitions. In addition, the current attention analysis mainly provided qualitative rather than quantitative interpretability. Future work should therefore focus on more reliable degradation-onset detection, stage-adaptive windowing, fatigue-informed feature construction, vibration-source attribution, domain adaptation or lightweight transfer learning, and stronger quantitative interpretability analysis. Overall, the present study demonstrated that integrating degradation-consistent HI construction with temporal-attention modelling provided an effective, interpretable, and more generalisable solution for rolling bearing RUL prediction under realistic distribution shifts.
Author Contributions
J.B.: conceptualization, data curation, investigation, methodology, writing—original draft, writing—review and editing. H.D.: resources, supervision, validation, writing—review and editing. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The data presented in this study are available on request from the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Ioannides, E.; Harris, T.A. A new fatigue life model for rolling bearings. J. Tribol. 1985, 107, 367–378. [Google Scholar] [CrossRef] [Scilit]
- Gohar, R.; Rahnejat, H. Fundamentals of Tribology; Imperial College Press: London, UK, 2008. [Google Scholar]
- Lynagh, N.; Rahnejat, H.; Ebrahimi, M.; Aini, R. Bearing-induced vibration in precision high-speed routing spindles. Int. J. Mach. Tools Manuf. 2000, 40, 561–577. [Google Scholar] [CrossRef] [Scilit]
- Chen, J.; Huang, R.; Chen, Z.; Mao, W.; Li, W. Transfer learning algorithms for bearing remaining useful life prediction: A comprehensive review from an industrial application perspective. Mech. Syst. Signal Process. 2023, 193, 110239. [Google Scholar] [CrossRef] [Scilit]
- Wei, Y.; Wu, D.; Terpenny, J. Bearing remaining useful life prediction using self-adaptive graph convolutional networks with self-attention mechanism. Mech. Syst. Signal Process. 2023, 188, 110010. [Google Scholar] [CrossRef] [Scilit]
- Kim, J.-W.; Park, K.-S. Remaining useful life prediction of bearings via semi-supervised transfer learning based on an anti-self-healing health indicator. Sensors 2025, 25, 3662. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Xu, Z.; Chow, C.W.; Rahman, M.M.; Rameezdeen, R.; Law, Y.W. Remaining useful life prediction across conditions based on a health indicator-weighted subdomain alignment network. Sensors 2025, 25, 4536. [Google Scholar] [CrossRef] [Scilit]
- Najdi, B.; Benbrahim, M.; Kabbaj, M.N. Adaptive Res-LSTM attention-based remaining useful lifetime prognosis of rolling bearings. Int. J. Progn. Health Manag. 2025, 16, 1–16. [Google Scholar] [CrossRef] [Scilit]
- Jin, X.; Ji, Y.; Li, S.; Lv, K.; Xu, J.; Jiang, H.; Fu, S. Remaining useful life prediction for rolling bearings based on TCN–Transformer networks using vibration signals. Sensors 2025, 25, 3571. [Google Scholar] [CrossRef] [Scilit]
- Qu, Q.; Wei, Q.; Wang, Y.; Liu, Y. Remaining useful life prediction of rolling bearings based on deep time–frequency synergistic memory neural network. Coatings 2025, 15, 406. [Google Scholar] [CrossRef] [Scilit]
- Sun, B.; Hu, W.; Wang, H.; Wang, L.; Deng, C. Remaining useful life prediction of rolling bearings based on CBAM-CNN-LSTM. Sensors 2025, 25, 554. [Google Scholar] [CrossRef] [Scilit]
- Xu, H.; Gao, Q.; Wang, M.; Lü, C.; Yang, Z.; Chen, J. Remaining useful life prediction of rolling bearings based on dual channel regression fusion network. J. Vib. Shock. 2025, 44, 322–332. [Google Scholar]
- Mohajerzarrinkelk, A.; Ahang, M.; Zoravar, M.; Abbasi, M.; Najjaran, H. Multi-channel Swin Transformer framework for bearing remaining useful life prediction. arXiv 2025, arXiv:2505.14897. [Google Scholar] [CrossRef] [Scilit]
- Wu, F.; Wu, Q.; Tan, Y.; Xu, X. Remaining useful life prediction based on deep learning: A survey. Sensors 2024, 24, 3454. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, H.; An, J.; Yang, J.; Xu, S.; Wang, Z.; Cao, Y.; Yuan, W. Remaining useful life prediction method of bearings based on the interactive learning strategy. Comput. Electr. Eng. 2025, 121, 109853. [Google Scholar] [CrossRef] [Scilit]
- Yang, L.; Jiang, Y.; Zeng, K.; Peng, T. Rolling bearing remaining useful life prediction based on CNN-VAE-MBiLSTM. Sensors 2024, 24, 2992. [Google Scholar] [CrossRef] [Scilit]
- Li, F.; Dai, Z.; Jiang, L.; Song, C.; Zhong, C.; Chen, Y. Prediction of the remaining useful life of bearings through CNN-Bi-LSTM-based domain adaptation model. Sensors 2024, 24, 6906. [Google Scholar] [CrossRef] [Scilit]
- Hou, D.; Chen, J.; Cheng, R.; Hu, X.; Shi, P. A bearing remaining life prediction method under variable operating conditions based on cross-transformer fusioning segmented data cleaning. Reliab. Eng. Syst. Saf. 2024, 245, 110021. [Google Scholar] [CrossRef] [Scilit]
- Gao, P.; Wang, J.; Shi, Z.; Ming, W.; Chen, M. Long-term temporal attention neural network with adaptive stage division for remaining useful life prediction of rolling bearings. Reliab. Eng. Syst. Saf. 2024, 251, 110218. [Google Scholar] [CrossRef] [Scilit]
- Wu, J.; He, D.; Li, J.; Miao, J.; Li, X.; Li, H.; Shan, S. Temporal multi-resolution hypergraph attention network for remaining useful life prediction of rolling bearings. Reliab. Eng. Syst. Saf. 2024, 247, 110143. [Google Scholar] [CrossRef] [Scilit]
- Zhang, M.; He, C.; Huang, C.; Yang, J. A weighted time embedding transformer network for remaining useful life prediction of rolling bearing. Reliab. Eng. Syst. Saf. 2024, 251, 110399. [Google Scholar] [CrossRef] [Scilit]
- Zhong, J.; Jiang, H.; Gu, K.; Zhong, J.; Zhong, S. Remaining useful life prediction of rolling bearing based on multi-region hypergraph self-attention network. Mech. Syst. Signal Process. 2025, 225, 112331. [Google Scholar] [CrossRef] [Scilit]
- He, D.; Zhao, J.; Jin, Z.; Huang, C.; Zhang, F.; Wu, J. Prediction of bearing remaining useful life based on a two-stage updated digital twin. Adv. Eng. Inform. 2025, 65, 103123. [Google Scholar] [CrossRef] [Scilit]
- He, D.; Zhao, J.; Jin, Z.; Huang, C.; Yi, C.; Wu, J. DCAGGCN: A novel method for remaining useful life prediction of bearings. Reliab. Eng. Syst. Saf. 2025, 260, 110978. [Google Scholar] [CrossRef] [Scilit]
- Lei, W.; Dong, X.; Cui, F.; Huang, G. A remaining useful life prediction method for rolling bearings based on hierarchical clustering and Transformer–GRU. Appl. Sci. 2025, 15, 5369. [Google Scholar] [CrossRef] [Scilit]
- Niola, V.; Cosenza, C.; Fornaro, E.; Malfi, P.; Melluso, F.; Nicolella, A.; Savino, S.; Spirto, M. Torque/Speed Equilibrium Point Monitoring of an Aircraft Hybrid Electric Propulsion System Through Accelerometric Signal Processing. Appl. Sci. 2025, 15, 2135. [Google Scholar] [CrossRef] [Scilit]
- Helm, D.; Timusk, M. Wavelet Denoising Applied to Hardware Redundant Systems for Rolling Element Bearing Fault Detection. J. Dyn. Monit. Diagn. 2023, 2, 102–114. [Google Scholar] [CrossRef] [Scilit]
- Rostaghi, M.; Azami, H. Dispersion Entropy: A Measure for Time-Series Analysis. IEEE Signal Process. Lett. 2016, 23, 610–614. [Google Scholar] [CrossRef] [Scilit]
- Yan, X.; Jia, M. Intelligent Fault Diagnosis of Rotating Machinery Using Improved Multiscale Dispersion Entropy and mRMR Feature Selection. Knowl.-Based Syst. 2019, 163, 450–471. [Google Scholar] [CrossRef] [Scilit]
- Lei, Y.; Han, T.; Wang, B.; Li, N.; Yan, T.; Yang, J. XJTU-SY Rolling Element Bearing Accelerated Life Test Datasets: A Tutorial. J. Mech. Eng. 2019, 55, 1–6. [Google Scholar] [CrossRef] [Scilit]
- Lee, J.; Qiu, H.; Yu, G.; Lin, J.; Rexnord Technical Services. Bearing Data Set; NASA Prognostics Data Repository, NASA Ames Research Center: Mountain View, CA, USA, 2007. [Google Scholar]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.