


Abstract
To characterize the dynamic behavior of the hydraulic system of a ground coal-bunker cleaning device under variable operating conditions, a mechanical–hydraulic co-simulation model was established by coupling ADAMS and AMESim. A pipeline pressure-drop model accounting for distributed frictional, local, and coiling-induced losses was developed based on the Darcy–Weisbach equation. The effects of the number of rod sections, hydraulic-hose length, valve-group actuation interval, and the equivalent hose-coiling state were evaluated. Increasing the rod sections from 1 to 30 raised the steady-state pressure of the lead-screw lifting motor by 42.0%, reduced its flow rate by 26.9%, and increased the pressure settling time by 167.2%. Increasing the hose length from 5 to 20 m reduced cylinder pressure from 25.20 to 11.30 bar and the pressure synchronization coefficient from 0.966 to 0.775. A 0.5 s valve-group interval reduced the composite disturbance by approximately 54%. At the representative flow rate of 22.59 L/min, the calculated total pressure loss increased from 0.664 MPa for the one-layer state to 0.742 MPa for the nine-layer state, an increase of approximately 11.7%, while frictional loss remained the dominant component. For different working conditions, finite-range sensitivity comparisons identified reflected inertia and load torque, hydraulic capacitance and distributed flow resistance, temporal overlap of branch flow demand, and distributed pipeline friction as the response-specific drivers of the four investigated operating scenarios. The model and results can provide a basis for optimizing actuation timing, hose layout, and operating strategies for coal-bunker cleaning devices.
1. Introduction
Ground coal bunkers are important storage and transfer facilities linking coal extraction, preparation, and transportation, and their operating conditions directly affect the continuity and stability of mine production systems. As coal production and transportation capacities increase, bunker blockage, arching, and material accumulation on bunker walls increasingly affect coal-transport efficiency and production safety [1,2]. Currently prevalent cleaning methods—including manual entry, air cannons, localized vibration, and mechanical arch breaking—remain limited in operational safety, automation, and cleaning coverage. Recent studies of in-bunker cleaning have shown that replacing personnel entry with mechanized, remotely controlled equipment can significantly reduce operational risks and improve control over material removal [3]. In the cleaning device studied here, rods are connected section-by-section to lower a high-pressure water-jet nozzle to the bottom of the bunker, while multiple hydraulic actuators work cooperatively to perform rod-connection, lifting, rotation, and luffing operations. The dynamic performance of the hydraulic system directly determines motion stability and operational reliability. It is therefore necessary to systematically investigate its hydraulic dynamic characteristics under the coupled effects of variable loads, shared-pump supply to multiple actuators, and long-distance coiled hoses, thereby providing a theoretical basis for hydraulic parameter matching, actuation-sequence design, and stable operation of the cleaning device.
Considerable recent research has addressed pressure fluctuations and hydraulic supply in multi-actuator systems. Wang et al. [4] investigated hydraulic-pressure pulsation attenuation and noted that suppression at the pressure source must be coordinated with control of the pulsation propagation path. Zhang et al. [5] developed a model of a valve-controlled helical hydraulic rotary actuator and performed parameter-sensitivity analysis, concluding that hydraulic load, leakage, and valve-orifice flow parameters jointly determine actuator torque and speed responses. Kittisares et al. [6] proposed an open-loop pressure–volume control method for a multi-degree-of-freedom hydraulic system and found that appropriate allocation of branch pressure and volume can improve coordination among multiple hydraulic actuators. Research on multiple-actuator supply has focused primarily on improving system energy efficiency through load sensing, independent metering, distributed supply, and power allocation. Multimode load-sensing control can adjust source pressure and power limits according to load conditions, whereas independent-supply and independent-metering configurations can reduce throttling losses and flow coupling between high- and low-load branches [7,8,9,10]. Recently proposed hybrid centralized–distributed supply systems, power-sharing electrohydraulic actuators, and hybrid hydraulic power sources have further improved power matching in multi-actuator systems [11,12,13]. Kadar et al. [14] showed that valve-spool switching and pipeline-pressure feedback may jointly induce pressure oscillations through nonlinear pressure-control-valve dynamics. Urbanowicz et al. [15] investigated pressure-wave interactions in hydraulic piping during simultaneous closure of multiple valves and found that pipe length, branch-connection configuration, and diameter variation significantly affect the superposition of incident and reflected pressure waves and may generate additional pressure peaks and secondary waves. However, these studies primarily targeted energy efficiency, steady-state flow distribution, or trajectory-tracking accuracy and paid insufficient attention to the transient pressure drop, reverse flow, pressure recovery time, and disturbance attenuation caused by actuation intervals between adjacent valve groups in common-pump systems. The effects of valve-group actuation sequence and interval on the dynamic responses of pressure-holding and actuating branches therefore warrant systematic analysis.
Long pipelines increase fluid inertia and compressible volume and introduce pipe-wall elasticity, distributed friction, and local resistance, thereby changing the propagation speed, amplitude, and attenuation of pressure waves. Studies have shown that propagation distance, boundary conditions, and fluid–structure shear coupling affect the phase and amplitude of pressure waves in pipes [16,17]. Andrade et al. [18] developed a transient fluid–structure interaction model for liquid-filled pipes that accounts for wall viscoelasticity and axial motion; their results showed that wall deformation produces bidirectional energy transfer between the fluid and the pipe wall through the coupling mechanism, thereby altering pressure-wave propagation speed. Analysis of broadband attenuators in aircraft hydraulic systems by Klaerner et al. [19] further showed that appropriate impedance matching in a hydraulic line can reduce fluid-borne noise and pressure pulsations. Unlike straight pipes, coiled pipes develop secondary flows across the pipe cross-section because of curvature-induced centrifugal effects; consequently, their frictional resistance depends not only on pipe length, diameter, roughness, and Reynolds number but also on curvature ratio and Dean number. Experiments on and modeling of pressure loss in coiled tubing by Oliveira et al. [20] showed that pipe length and coil curvature have coupled effects on total pressure drop and that applying straight-pipe friction relations directly to coiled tubing can produce substantial errors. Wei et al. [21] reported that changes in flow velocity and external random excitation can affect the vibration response of fluid-conveying pipes. The review by Sigalotti et al. [22] noted that coiling geometry alters the laminar–turbulent transition, velocity distribution, and friction factor, whereas pipe deformation, wall flexibility, and dynamic coiling remain comparatively underexplored. Most current hydraulic-system simulations treat hose length and curvature as fixed, making it difficult to characterize the additional resistance and dynamic pressure drop caused by continuous changes in the equivalent coiling state during reel operation.
In mechanical–hydraulic co-simulation, Raoofian et al. [23] studied nonsmooth reduced-order models for mechanical-system co-simulation and showed that consistent transfer of interface variables improves multimodel coupling stability. Gao et al. [24] developed and analyzed a coupled dynamic model of a hydraulic vibratory hammer, showing that bidirectional coupling between multibody dynamics and the hydraulic model can represent load feedback with reasonable accuracy. Gan et al. [25] performed multibody-dynamics–discrete-element co-simulation of an excavator and predicted the bidirectional coupling between loads and mechanism motion under complex operating conditions. Zhao et al. [26] investigated the dynamic response of a coal-rock caving impact tail beam in a hydraulic support and showed that impact loads substantially alter mechanism vibration and peak forces. Studies by Sun et al. [27], Ding et al. [28], and Xin et al. [29] further demonstrated that multiplatform co-simulation can be used to analyze the multiple-time-scale responses of hydraulic dampers, tensioning mechanisms, and working devices in various types of construction machinery. Separately, Kumar [30] also theoretically analyzed the effects of helical-pipe curvature on flow rate and frictional resistance. These studies provide an important basis for hydraulic-system dynamic modeling under complex mechanical loading and analysis of flow characteristics in curved pipes. However, most existing work considers fixed loads, constant pipeline parameters, or a single actuator and does not jointly account for the variable load caused by successive rod extension, changes in long-hose length and coiling state, or flow fluctuations caused by shared-pump actuation of multiple branches. The pressure–flow coupling mechanisms and parametric effects of the cleaning device under continuous rod connection and coordinated multi-mechanism operating conditions therefore remain to be elucidated.
Overall, considerable progress has been made in hydraulic-system pressure fluctuations, multiple-actuator supply, long-pipeline transient behavior, and mechanical–hydraulic coupled modeling. However, most studies address fixed loads, constant pipeline parameters, or single-actuator conditions. In a ground coal-bunker cleaning device, the increase in load and inertia caused by successive rod connection, long-distance oil delivery through a hose and changes in its coiling state, and flow redistribution caused by common-pump switching of multiple actuators occur concurrently. The resulting pressure attenuation, response lag, and branch-disturbance behavior under their coupled effects have not been systematically investigated. Accordingly, this study focuses on the hydraulic system of a ground coal-bunker cleaning device and develops an ADAMS–AMESim (version 2020) mechanical–hydraulic co-simulation model. Model consistency is assessed by comparing numerical results with those of a standalone hydraulic model, and bidirectional transfer is implemented between mechanical-system variables—displacement, velocity, and load—and hydraulic-system outputs such as actuator force and motor torque. Meanwhile, on the basis of the Darcy–Weisbach equation and studies of pressure losses in coiled and helical pipes, total pipeline pressure drop is decomposed into distributed frictional pressure loss, local pressure loss, and coiling-induced additional pressure loss. A MATLAB2019b variable-resistance module is developed to simulate hose coiling and uncoiling. The number and total mass of rod sections, effective hydraulic-hose length, actuation interval between adjacent valve groups, and equivalent hose-coiling state are then taken as key variables. The settling processes of system pressure and flow rate, the dynamic response of the luffing cylinder, disturbances in the pressure-holding branch, and variations in pipeline pressure drop are investigated to evaluate system stability during rod connection under heavy loads, long-distance hydraulic-fluid transmission, and valve-group switching. The results provide a theoretical basis for pump–valve parameter matching, actuation-sequence optimization, and the development of coal-bunker cleaning strategies.
2. Theory and Methods
2.1. Construction of the Mechanical–Hydraulic Coupled Model
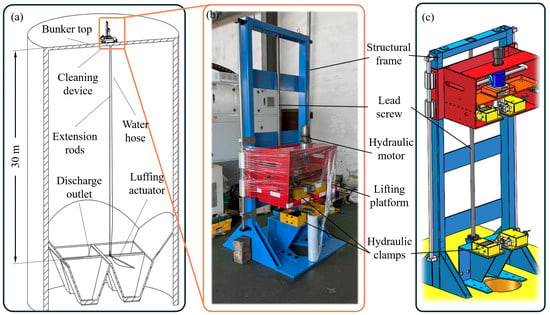
The coal-bunker cleaning device consists of a vertical gantry, upper and lower hydraulic clamps, a lead-screw lifting mechanism driven by a hydraulic motor, a lifting platform, a rod-connection motor assembly, a swing cylinder and its telescoping platform, a rack-and-pinion rotary actuator, multiple long rod sections, a luffing mechanism, hydraulic valve groups, an electric flatcar chassis, a water tank, and a hydraulic power unit. A schematic of the cleaning operation, a photograph of the device, and a three-dimensional model are shown in Figure 1. The device is installed in the belt gallery above the ground coal bunker and moves between cleaning access openings on an electric flatcar. The lifting platform, which is driven by the hydraulic motor through the lead-screw lifting mechanism, operates alternately with the two hydraulic clamps to connect successive rod sections. The rack-and-pinion rotary actuator drives the swing mechanism to adjust the cleaning direction, while a hydraulic cylinder drives the luffing mechanism to adjust the pitch angle of the water-jet nozzle. The high-pressure water jet breaks up and flushes coal adhering to the bunker wall and material in blocked areas. Because the hydraulic clamps, lifting mechanism, and luffing mechanism are all powered by the same hydraulic system, opening or closing any branch or changing its load redistributes pressure and flow between the main line and the branches. System dynamics must therefore be analyzed with explicit consideration of coupling among multiple actuators.
Figure 1.
Coal-bunker cleaning device and three-dimensional model: (a) schematic of the cleaning operation; (b) photograph of the device; (c) three-dimensional model of the device.
2.2. Governing Equations of the Coupled Mechanical–Hydraulic System
In the ADAMS rigid-body dynamics model, the constrained equations of motion for the mechanical system of the coal-bunker cleaning device can be expressed as
where , , and are the generalized displacement, generalized velocity, and generalized acceleration of the system, respectively; is the generalized mass matrix; h is the term containing the Coriolis force, centrifugal force, gravity, and structural damping; is the transposed Jacobian matrix of the constraint equations; λ is the Lagrange multiplier associated with the constraint reaction forces; Fh and Tm are, respectively, the hydraulic-cylinder force and hydraulic-motor torque output by AMESim; and GF and GT map the hydraulic force and torque into generalized-force space. Qext is the vector of other external generalized forces.
For a double-acting hydraulic cylinder, the cap-end and rod-end pressure dynamics, accounting for fluid compressibility, internal leakage, and the volume changes induced by piston motion, can be written as
where
The effective driving force transmitted by the hydraulic cylinder to the mechanical system is
where PA and PB are the cap-end and rod-end pressures, respectively; QA and QB are the corresponding chamber flow rates; AA and AB are the effective areas on the two sides of the piston; βe is the effective bulk modulus of the hydraulic fluid; Ct is the total leakage coefficient of the hydraulic cylinder; Bc is the viscous damping coefficient; Ff is the seal-friction force; x is the piston displacement; and VA0 and VB0 are the initial cap-end and rod-end chamber volumes, respectively.
The flow-continuity equation for the hydraulic motor can be written as
where Dm is the hydraulic-motor displacement per radian, Dm = Vg/(2π).
The actual output torque of the ball screw is then
In Equations (6) and (7), Δpm is the pressure differential between the motor inlet and outlet; Qm is the motor inlet flow rate; ωm is the motor angular velocity; Cm is the internal-leakage coefficient; Veq is the equivalent pressurized volume; ηtm is the mechanical torque efficiency, representing the internal mechanical efficiency with which the motor pressure differential is converted into shaft torque, and Bm and Tc are the viscous-friction coefficient and Coulomb-friction torque, respectively.
During co-simulation, ADAMS feeds the hydraulic-cylinder displacement and velocity, together with the hydraulic-motor rotation angle, angular velocity, and mechanical load, back to AMESim. AMESim then calculates the hydraulic-cylinder force and motor output torque from the valve-orifice flow rate, chamber pressure, and fluid-compression characteristics and applies these quantities to the ADAMS multibody-dynamics model, thereby forming the bidirectional closed-loop coupling expressed in Equations (8) and (9). In these equations, YM is the mechanical-state vector supplied to AMESim, YH is the hydraulic-output vector supplied to ADAMS, and TL is the equivalent mechanical load torque:
2.3. Consistency Validation of the Coupled Model
An ideal mechanical–hydraulic interface should ensure consistency in the magnitudes, directions, and time-domain evolution of displacement, velocity, and load variables. Accordingly, the co-simulation model is compared with the standalone hydraulic model in terms of three aspects: kinematic response, hydraulic response, and power transmission. The models/specifications and key parameters of the principal power components and hydraulic actuators used in the mechanical–hydraulic co-simulation model are listed in Table 1.
Table 1.
Key parameters of hydraulic components.
At a temperature of 25 °C, the ISO VG 46 hydraulic oil used in the simulation model has a density of 865 kg/m3. Based on the ASTM D341 viscosity–temperature relationship, its dynamic viscosity and kinematic viscosity were determined to be 85 mPa·s and 98 mm2/s, respectively, and its bulk modulus was set to 1.5 GPa. The actuator-branch hydraulic hose used in the dynamic-response model is an EN-853-2SN-3/8″ hose, with an inner diameter of 9.9 mm, an outer diameter of 18.7 mm, and a wall thickness of 4.4 mm. The equivalent bulk modulus of the hose wall was set to 1.3 GPa. The rated parameters of the aforementioned components, including the pump, actuators, hoses, and hydraulic oil, were selected from the manufacturers’ nameplate or specification data. The masses of the mechanical components and the contact-interface relationships were obtained from the ADAMS dynamic model, in which the equivalent friction coefficients were assigned according to the type of relative motion at each contact interface. The corresponding parameters are summarized in Table 2.
Table 2.
Key parameters of the co-simulation model.
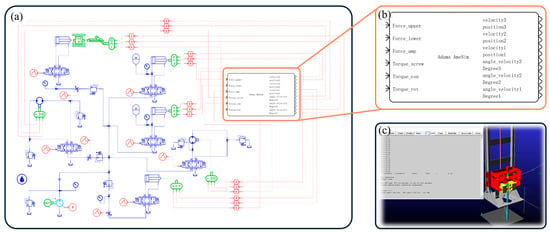
The co-simulation platform developed in this study is shown in Figure 2; mechanical–hydraulic coupling is implemented through data exchange between ADAMS and AMESim. On the mechanical side, ADAMS retains the mass, inertia, constraints, and geometric relationships of the lifting platform, lead-screw drive, clamping mechanism, and luffing mechanism, allowing external mechanical loads to be mapped in real time to the hydraulic actuators as the mechanisms move. On the hydraulic side, AMESim retains the flow continuity, fluid compressibility, and leakage characteristics of the pump source, valve orifices, hydraulic cylinders, hydraulic motors, and long hoses to describe pressure build-up, flow distribution, and coupled disturbances among branches. During co-simulation, ADAMS transfers actuator displacement, velocity, rotation angle, angular velocity, and mechanical load to AMESim. AMESim calculates hydraulic-cylinder forces and hydraulic-motor torques from valve-orifice flow rates, chamber pressures, and fluid-compression characteristics and feeds them back to ADAMS. At the co-simulation interface, gain coefficient K is specified for displacement, velocity, force, and torque to ensure dimensional consistency between the two software packages.
Figure 2.
Mechanical–hydraulic coupled model and co-simulation environment of the coal-bunker cleaning device: (a) mechanical–hydraulic coupled model; (b) AMESim–ADAMS communication interface; (c) ADAMS dynamic model and co-simulation environment.
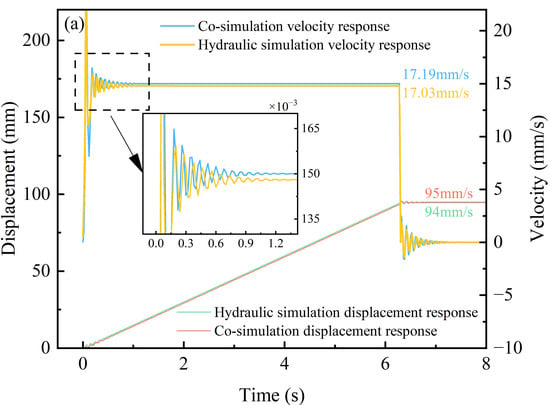
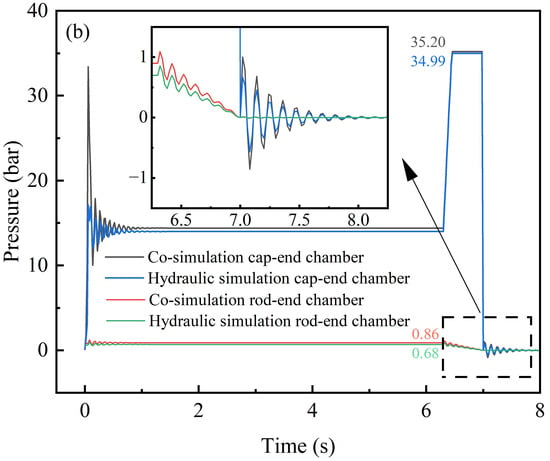
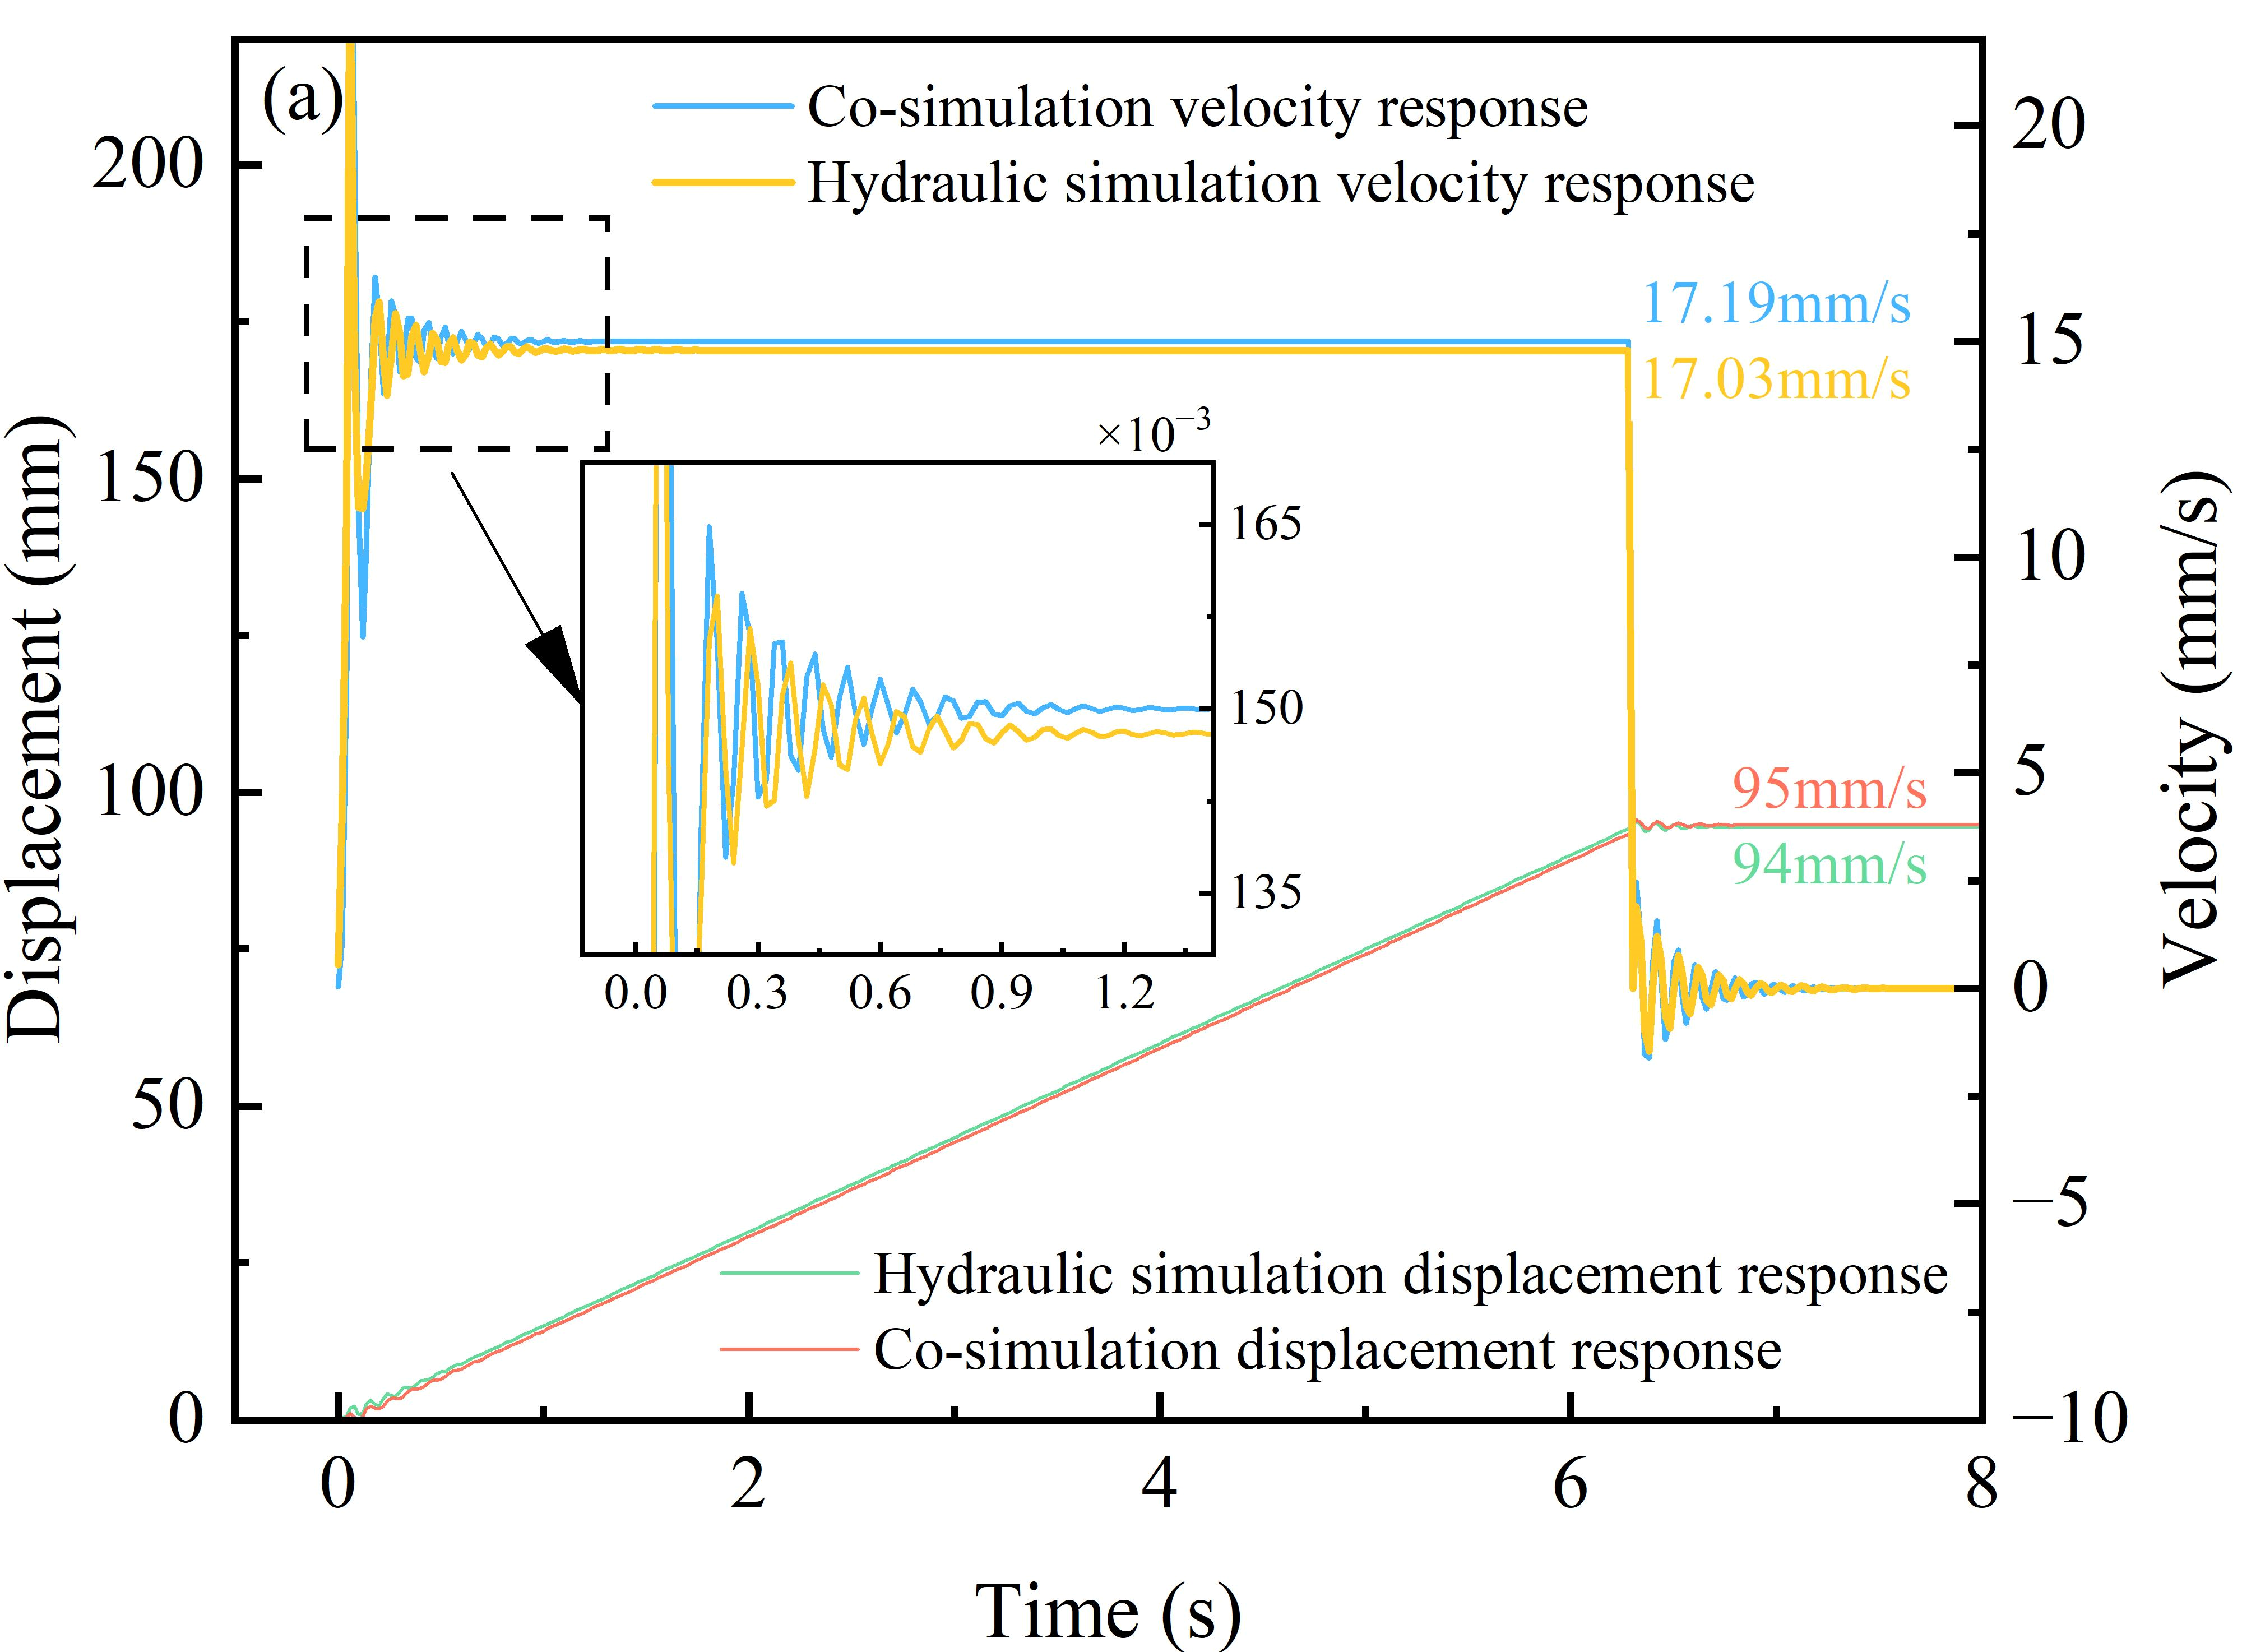
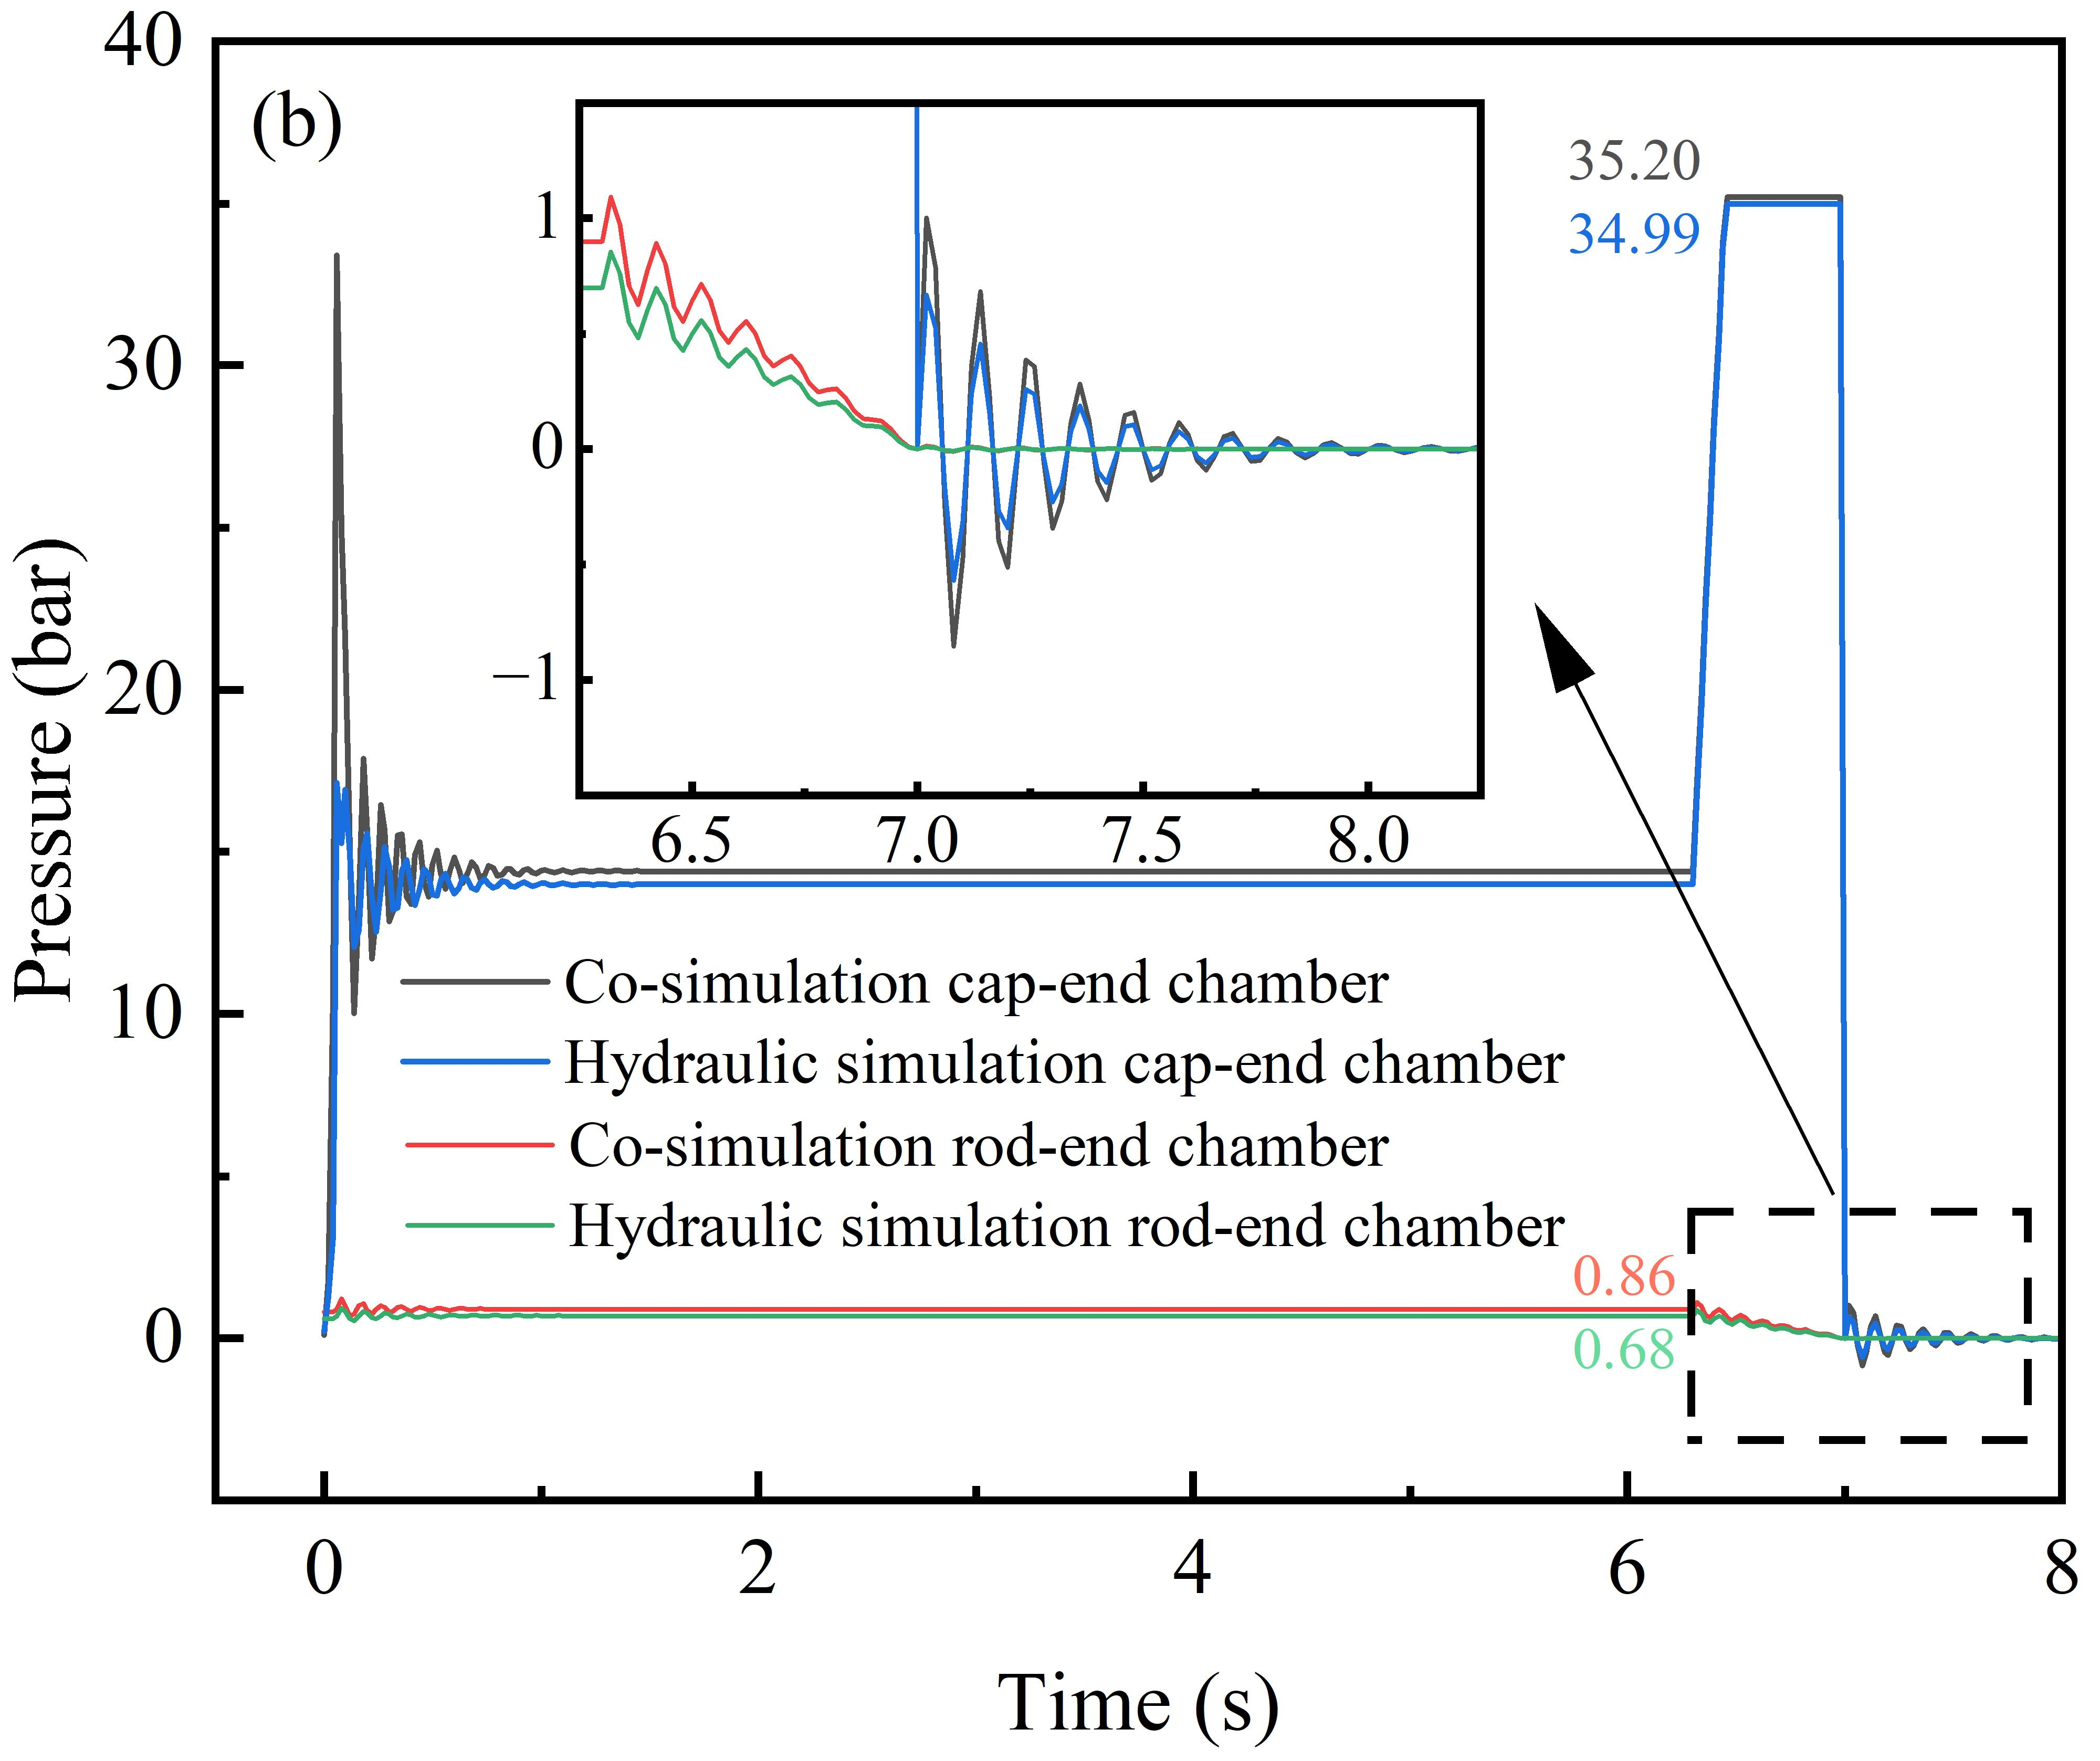
The platform displacement predicted by both models passes through three stages: startup, approximately uniform upward motion, and steady holding. The overall trends of the displacement and velocity responses are essentially consistent. As shown in Figure 3a, the steady-state displacements obtained from the co-simulation model and the standalone hydraulic model are approximately 0.095 m and 0.094 m, respectively, with an absolute difference of 0.001 m and a relative difference of approximately 1.06%; the corresponding steady-state velocities are approximately 0.01719 m/s and 0.01703 m/s, respectively, with a relative difference of approximately 0.94%. These results indicate good consistency in the displacement feedback, hydraulic-cylinder stroke conversion, and interface-direction settings. In Figure 3b, the pressures predicted by the two models during low-pressure operation of the cap-end chamber are approximately 14.40 bar and 14.00 bar, respectively, with a relative difference of approximately 2.88%; the corresponding pressures during the high-load stage are approximately 35.20 bar and 34.99 bar, respectively, with a relative difference of approximately 0.57%. The absolute difference between the rod-end chamber pressures is approximately 0.18 bar.
Figure 3.
Comparison of hydraulic-cylinder dynamic responses predicted by the two models: (a) displacement and velocity responses; (b) chamber-pressure responses.
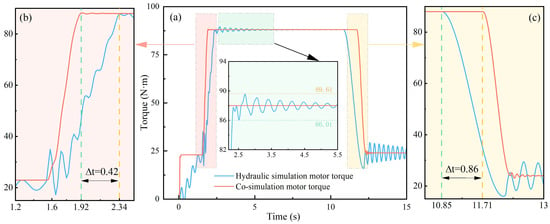
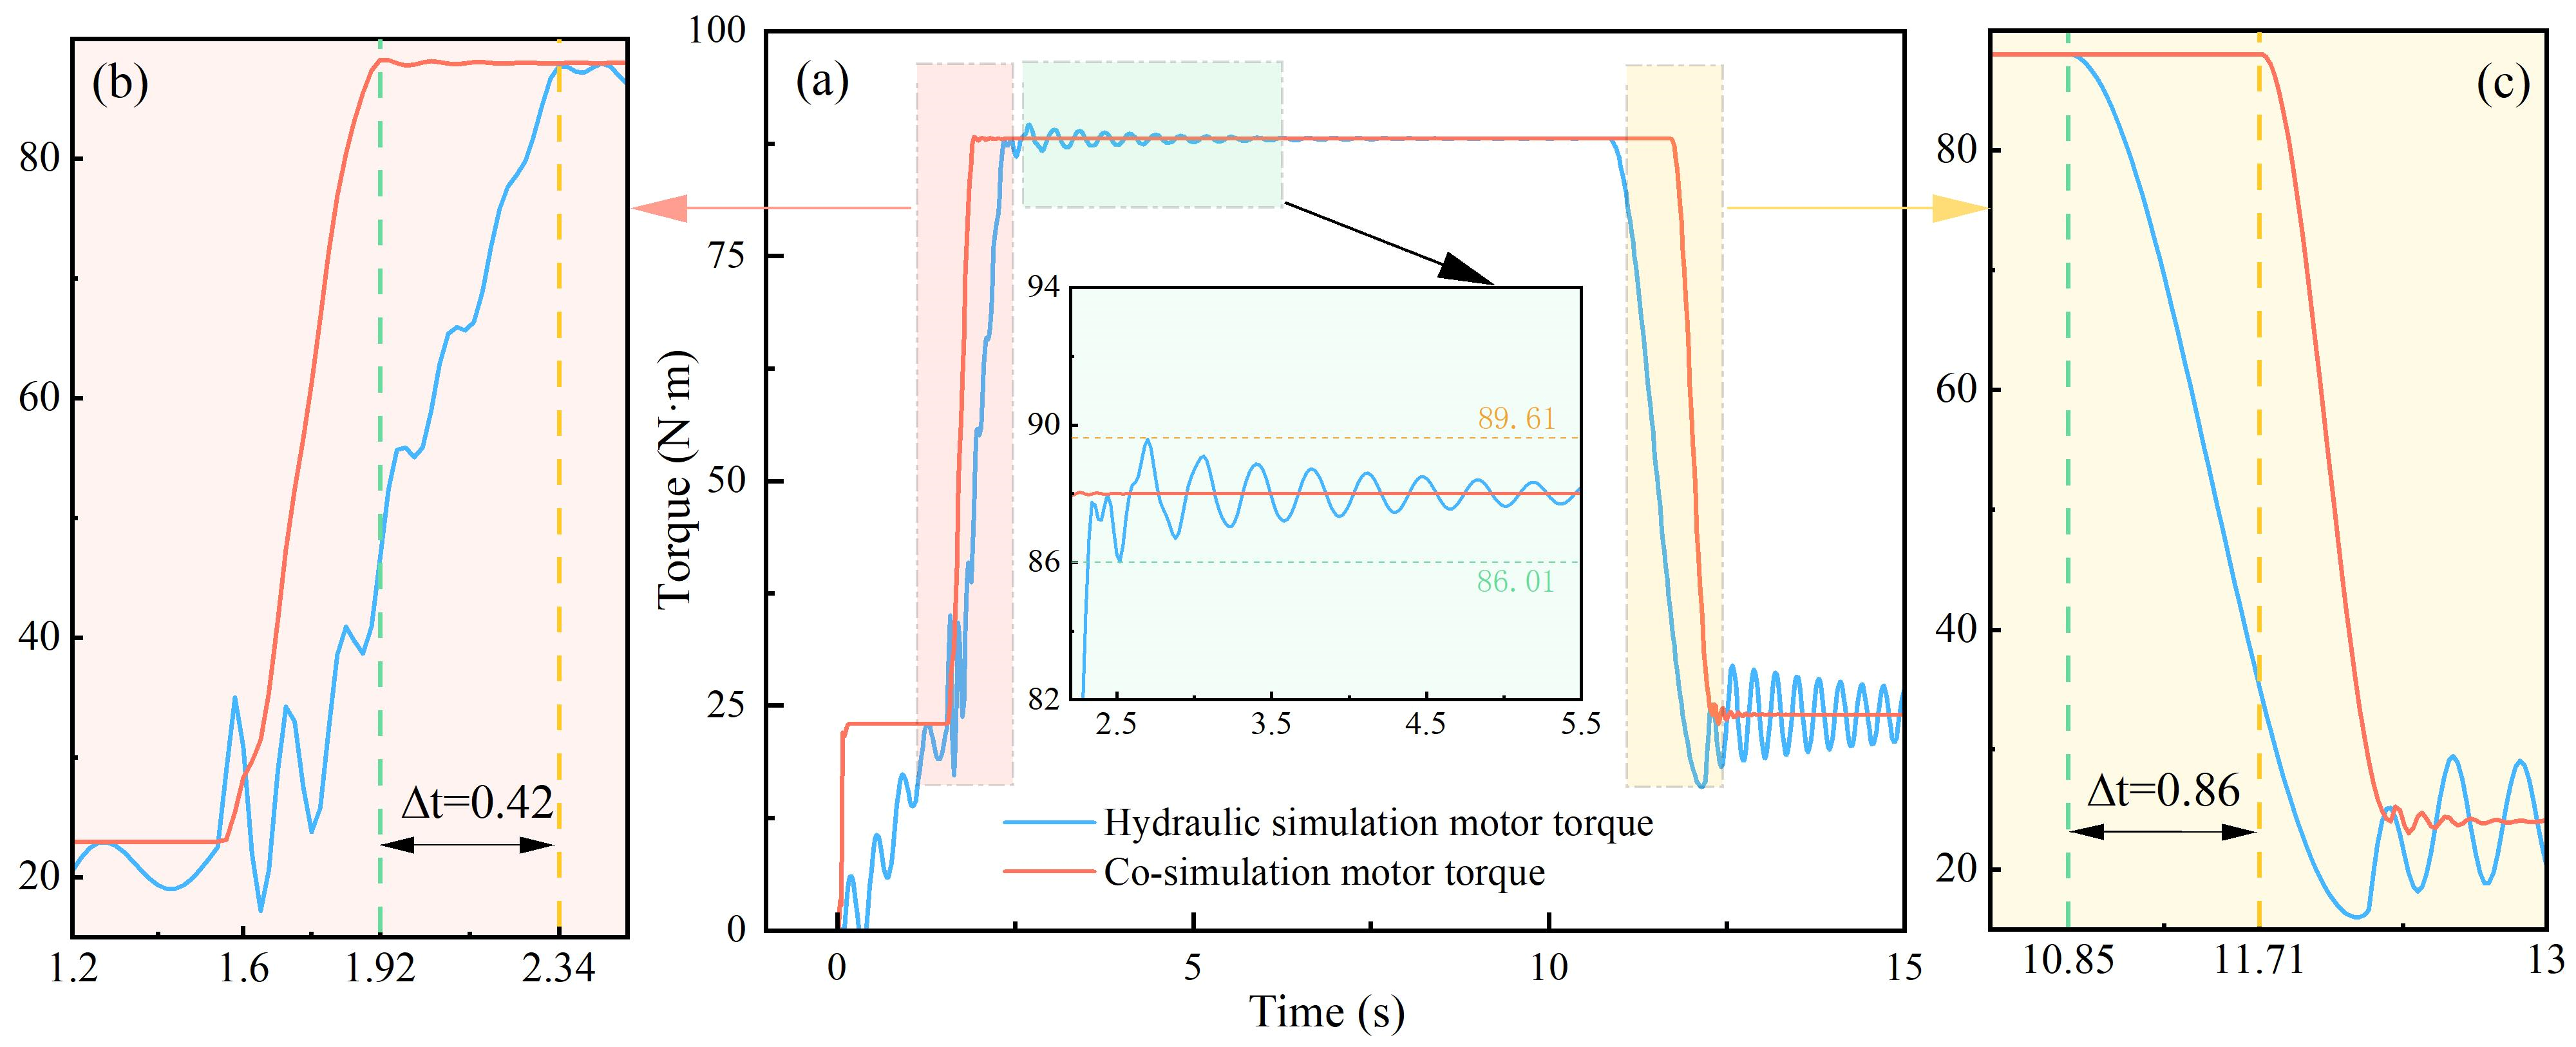
Figure 4 shows that the hydraulic-motor torque predicted by both models is approximately 88 N·m during the high-load steady-state stage, and the difference between the steady-state mean values is less than 0.01 N·m. During the high-torque plateau, the mean absolute error is approximately 0.21 N·m and the root-mean-square error is approximately 0.36 N·m, with the latter accounting for approximately 0.41% of the plateau value. At startup, the standalone hydraulic model lags the co-simulation model by approximately 0.42 s; at shutdown, the co-simulation model lags the standalone hydraulic model by approximately 0.86 s. The oscillations differ to some extent; nevertheless, the direction of torque variation and the steady-state operating point are consistent between the two models. In summary, the relative differences between the co-simulation model and the standalone hydraulic model in platform displacement, velocity, and primary operating pressure of the cap-end chamber are approximately 1.06%, 0.94%, and 2.88%, respectively, while the hydraulic-motor torque RMSE (root-mean-square error) is approximately 0.36 N·m (0.41% of the steady-state plateau value). The relative differences in the major steady-state response quantities remain within 3%, and their trends and steady-state operating points are consistent. These results demonstrate that the established interface can stably transmit motion, pressure, and torque information and that the coupled model can be used for subsequent response analyses under different rod loads, hose lengths, and valve-group actuation timing.
Figure 4.
Comparison of hydraulic-motor torque responses: (a) complete torque time histories with an enlarged steady-state view; (b) torque response during startup; (c) torque response during shutdown.
Although the two models show good agreement under steady-state conditions, their transient responses are not completely synchronized. At startup, the standalone hydraulic model lags the co-simulation model by approximately 0.42 s, whereas at shutdown, the co-simulation response lags the standalone hydraulic model by approximately 0.86 s. These time offsets mainly arise from the different representations of the mechanical subsystem. The co-simulation model retains the physical mechanism, including its mass and inertia, constraint reactions, friction, and structural damping, whereas the standalone hydraulic model represents the mechanical load using an idealized equivalent load. In addition, the communication interval between ADAMS and AMESim and the integration steps adopted by the two solvers may introduce a small phase offset during rapidly changing conditions. Because these effects are coupled, the present comparison does not isolate their individual contributions. Nevertheless, the differences are concentrated in the startup and shutdown transients and do not alter the close agreement between the steady-state operating points.
Following the internal numerical verification, the existing discrete parameter scans were recast in a common dimensionless form to compare the response mechanisms discussed in Section 3. The finite-range logarithmic sensitivity coefficient between two positive endpoints is defined as
where x1 and x2 are the two sampled parameter values and y1 and y2 are the corresponding response values. The resulting dimensionless coefficient measures the average proportional response over the selected finite range. For interval analysis, the expression is evaluated for each adjacent pair and plotted at the upper endpoint of that interval; for full-range comparisons, the first and last sampled points are used. Because the valve-group interval begins at 0 s, its logarithmic sensitivity coefficient is undefined, so its effect is instead quantified by reverse-flow attenuation and the change in clamping-force retention.
3. Analysis of the Hydraulic-System Characteristics of the Ground Coal-Bunker Cleaning Device
3.1. Effect of the Number of Rod Sections on System Response
To investigate how the increase in load caused by sequential rod connection affects the dynamic characteristics of the hydraulic system, the number of rod sections N was varied to simulate the rod-connection process while the hydraulic-pump speed, valve-orifice opening, hydraulic-fluid properties, and other parameters were held constant. The pressure, flow rate, and settling time of the hydraulic motor of the lead-screw lifting mechanism were then analyzed. Settling time was defined as the interval from the initial system response until the response quantity entered and continuously remained within a ±2% error band around its steady-state value.
After the total rod mass is referred to the motor shaft through the lead-screw transmission, the equivalent rotational inertia of the system can be expressed as
where J0 is the baseline equivalent inertia of the motor, lead screw, and platform assembly; mL(N) is the equivalent load mass that varies with the number of rod sections; and h is the lead-screw pitch. As the number of rod sections N increases, Jeq increases, and the natural frequency of the system can be approximated as
where Kh is the equivalent hydraulic stiffness jointly determined by the bulk modulus of the hydraulic fluid, the pressurized volume, and the compliance of the pipeline. For an approximately second-order system, the settling time can be expressed as
where ts is the settling time and ζ is the damping ratio of the system. Equations (11)–(13) show that Jeq increases, whereas Kh changes only slightly because it is constrained by hydraulic-fluid compressibility and pipeline elasticity. Consequently, ωn decreases, the attenuation of pressure and flow-rate oscillations slows, the settling time increases with load, and the increase in settling time becomes more rapid when N > 15. These results indicate that the increase in equivalent inertia caused by load growth is an important reason for the longer settling time.
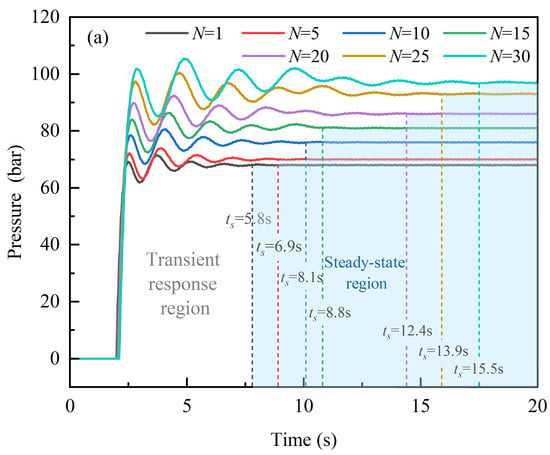
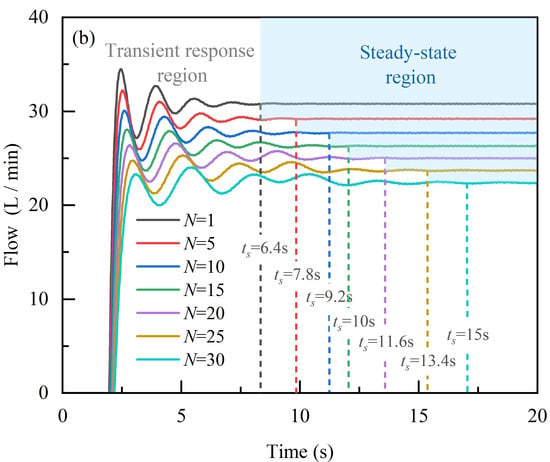
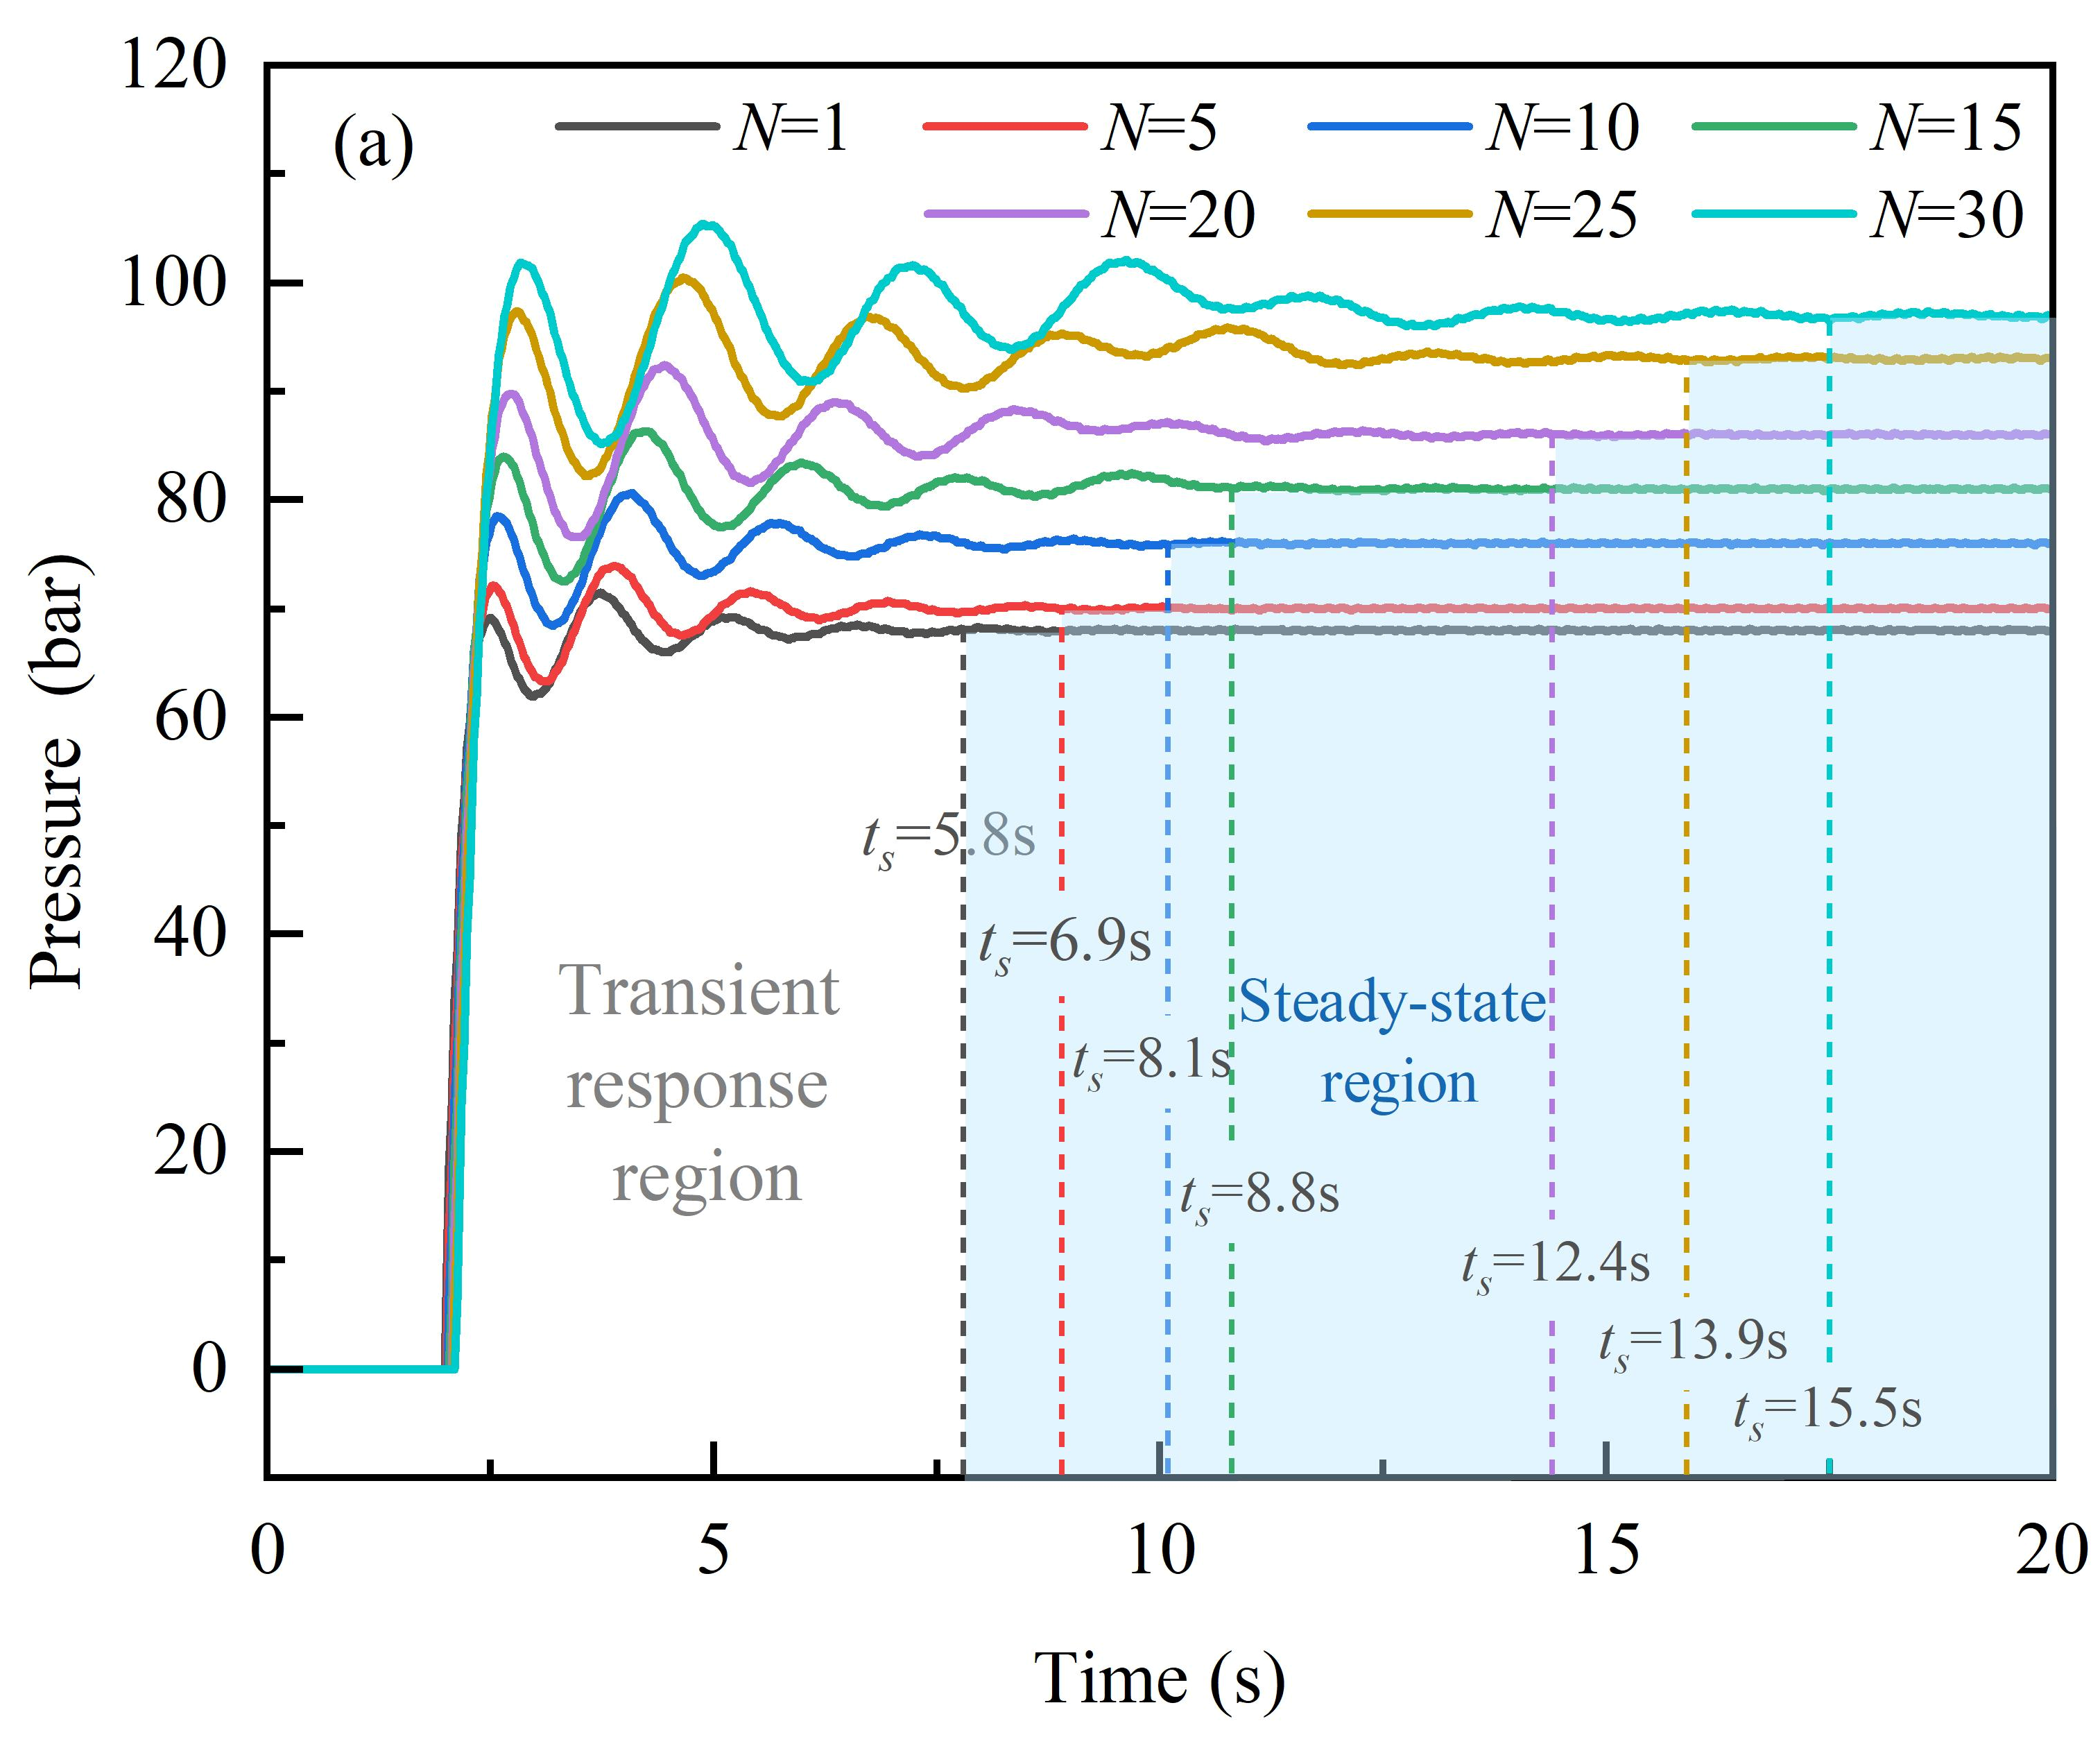
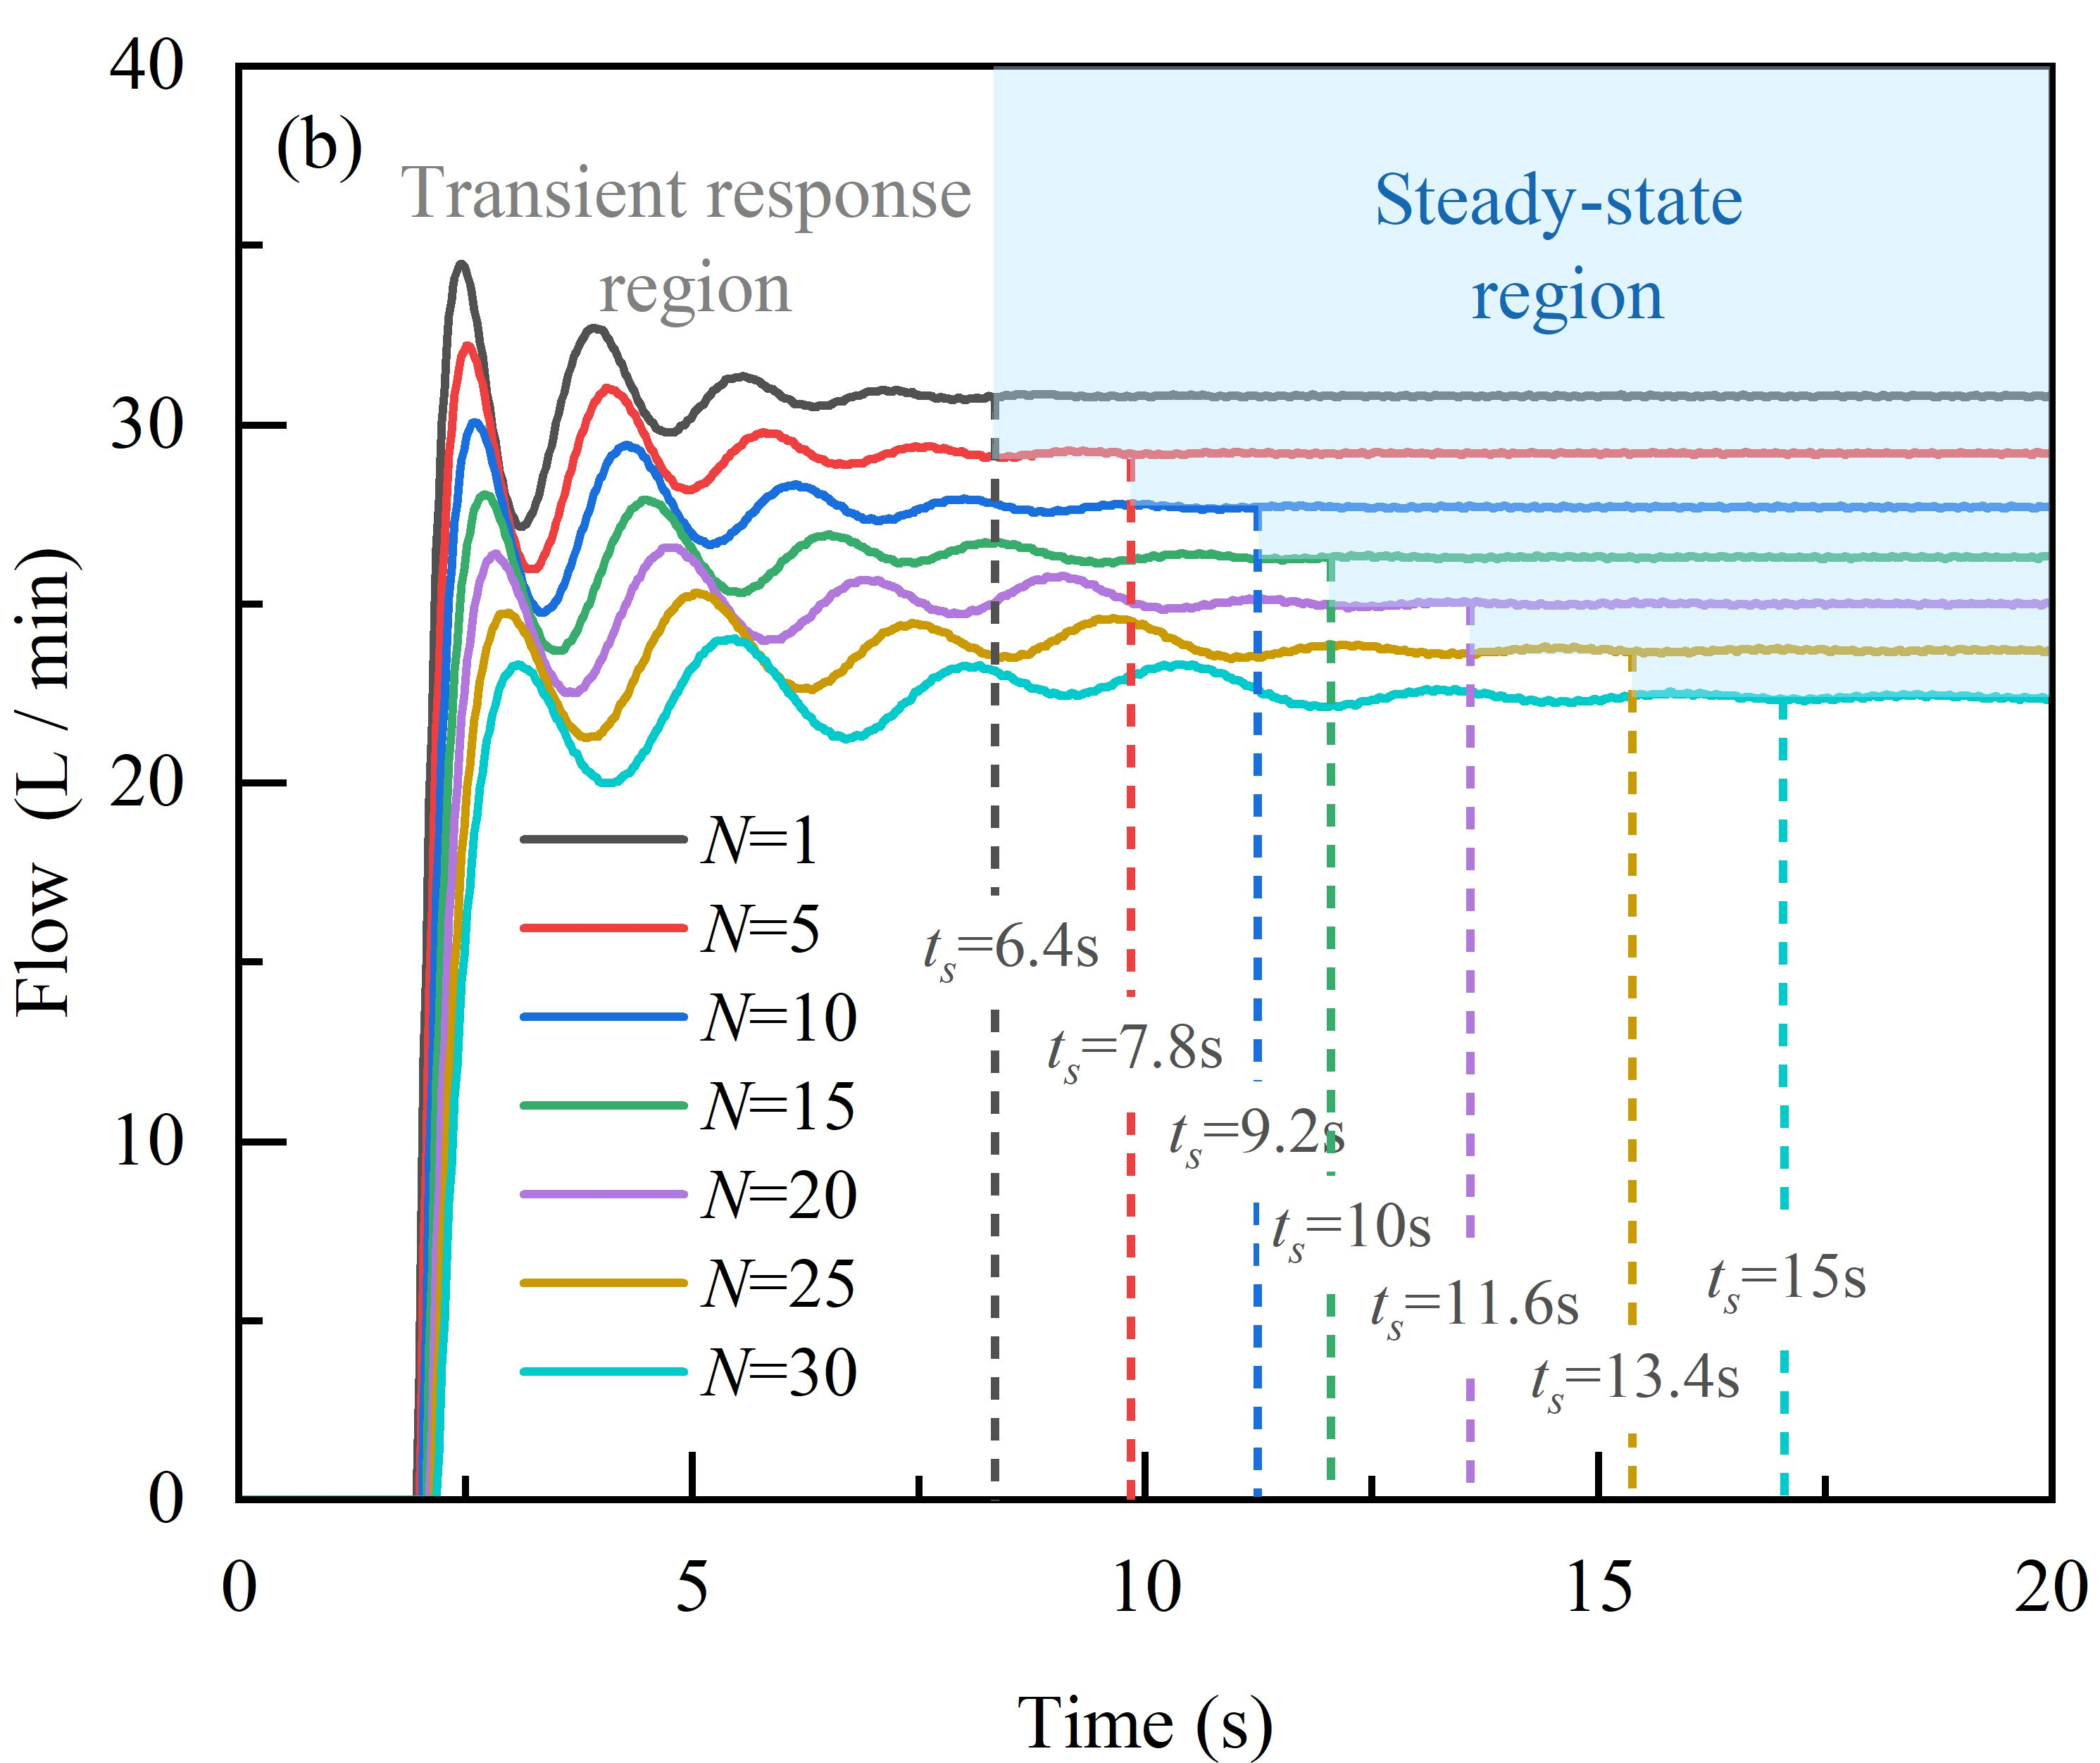
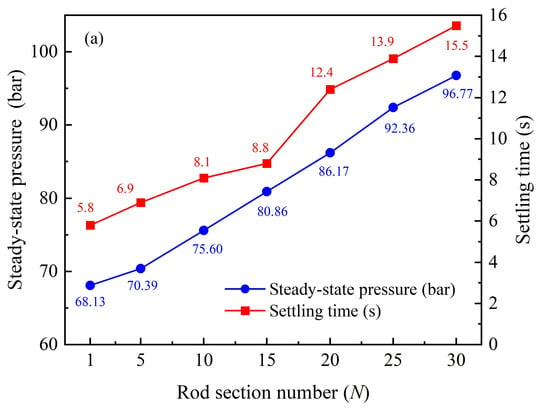
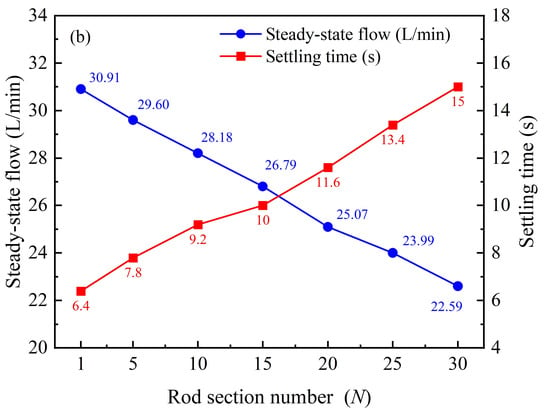
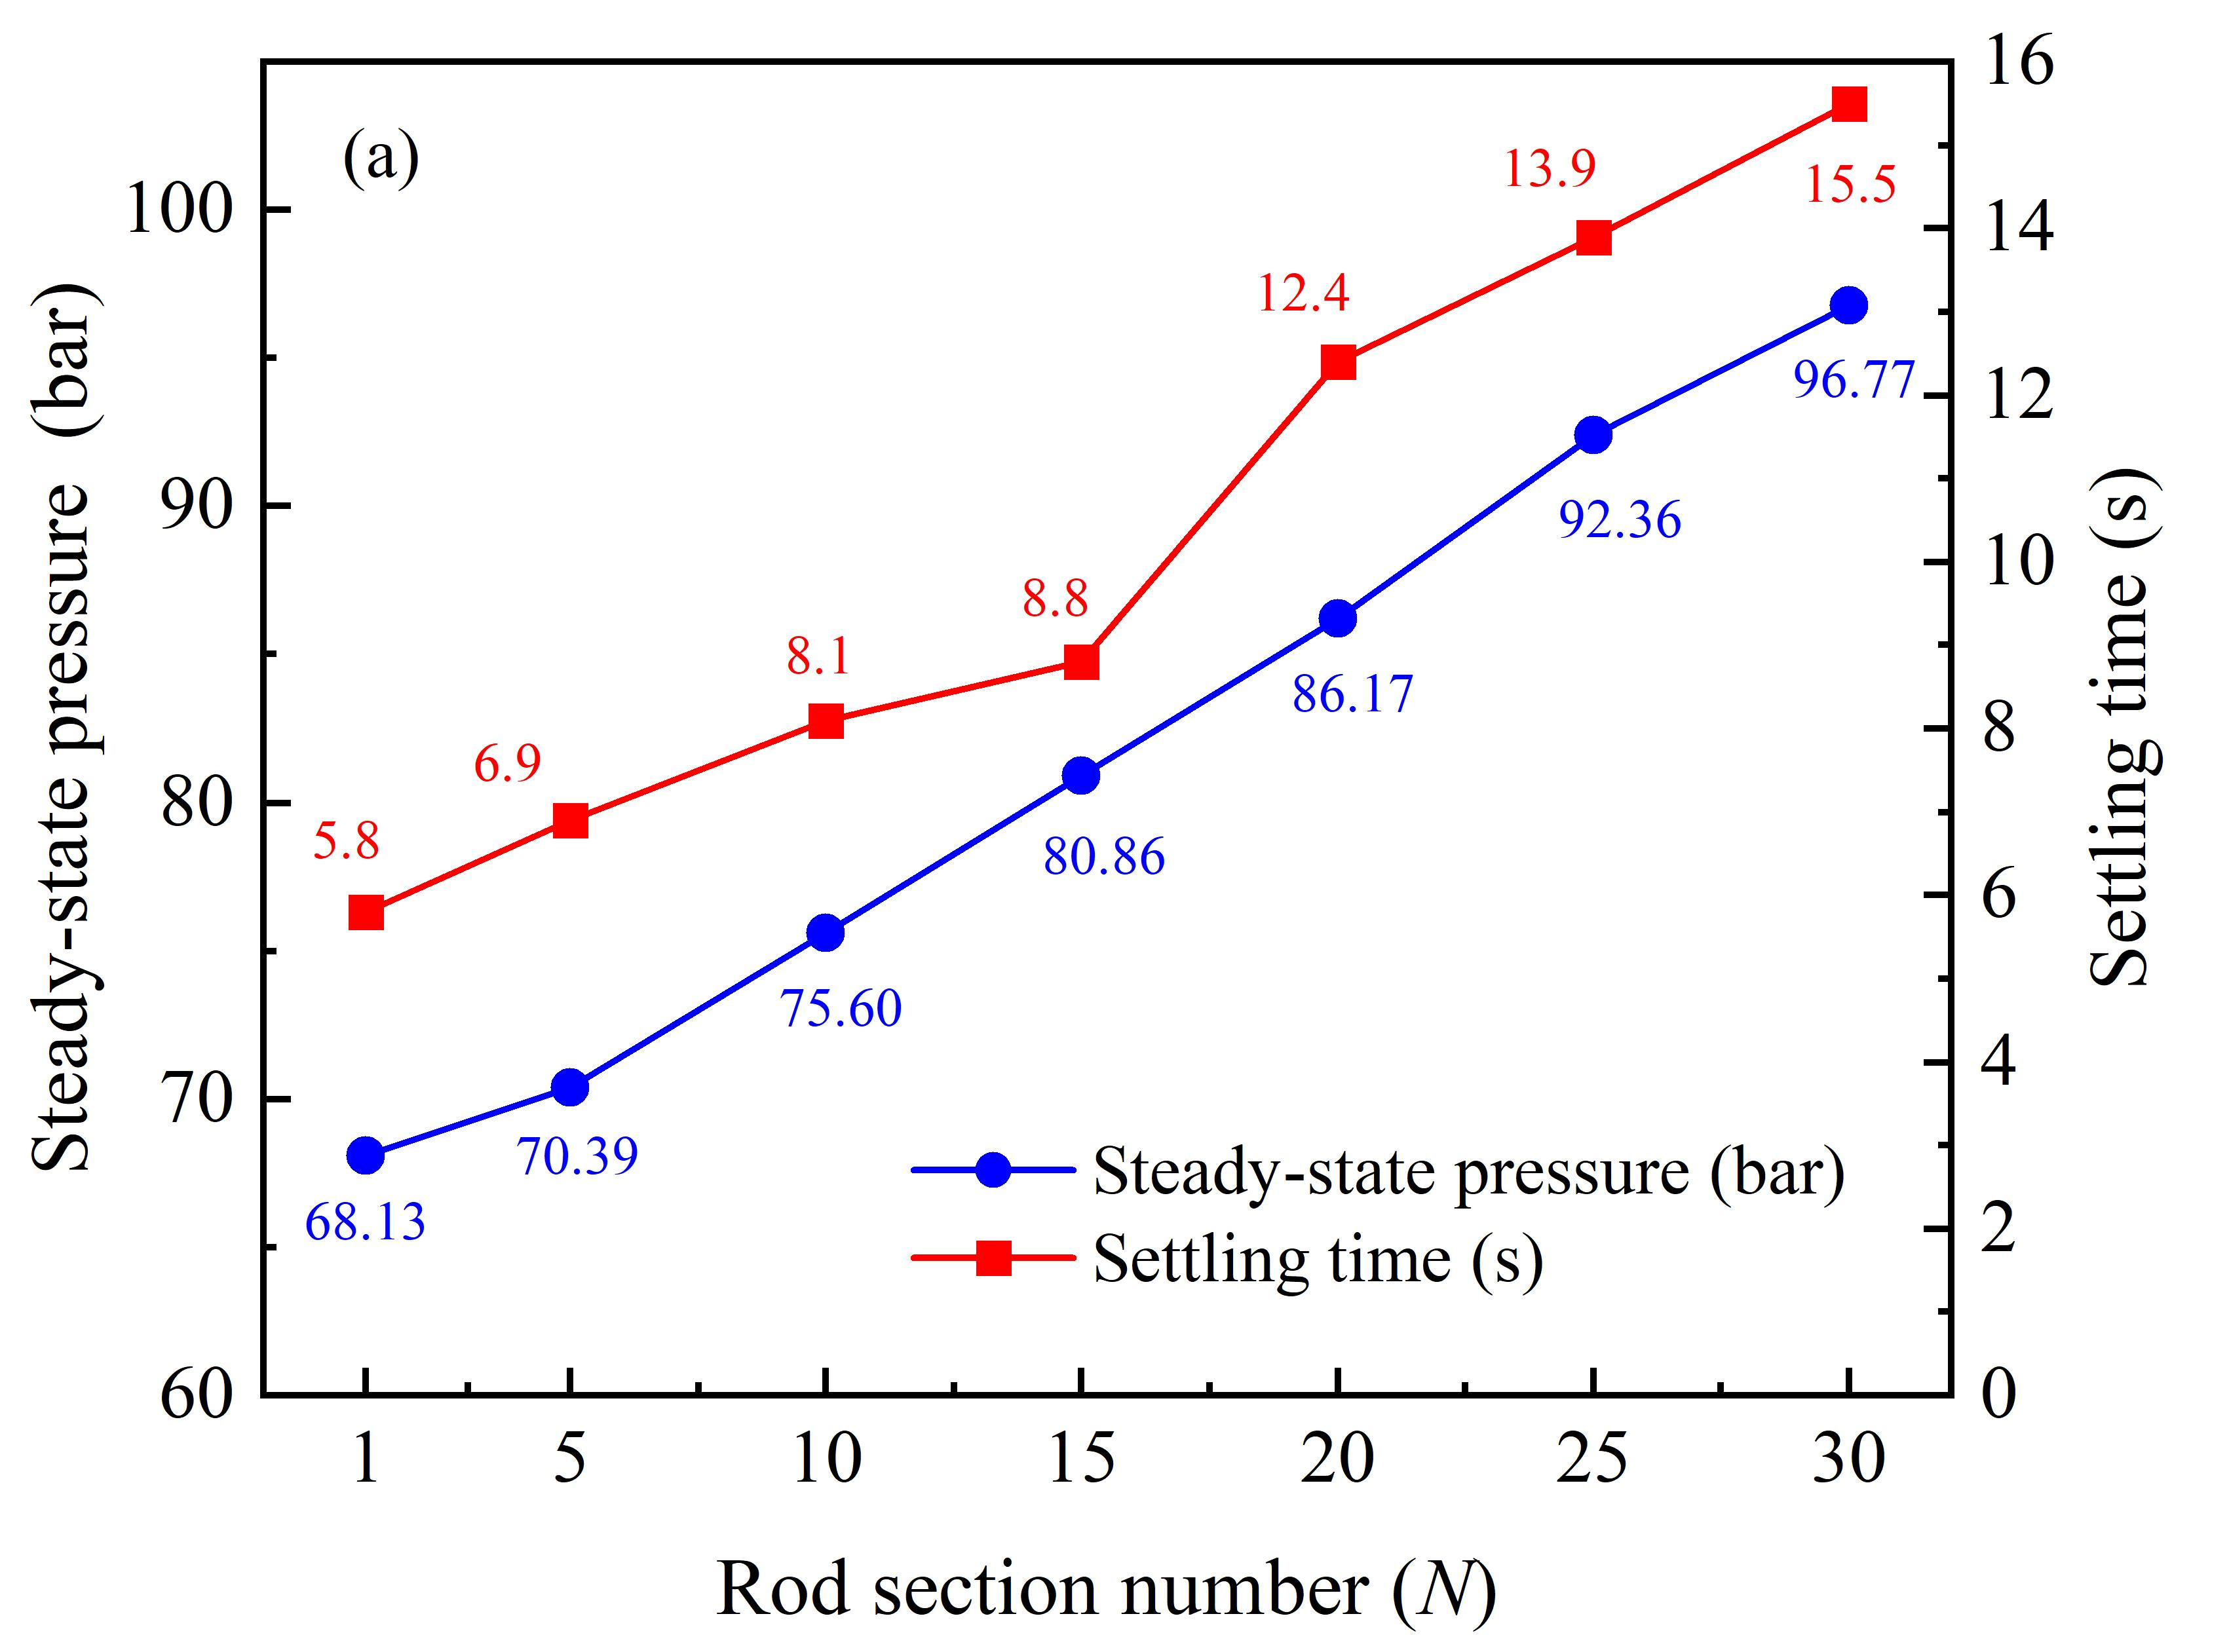
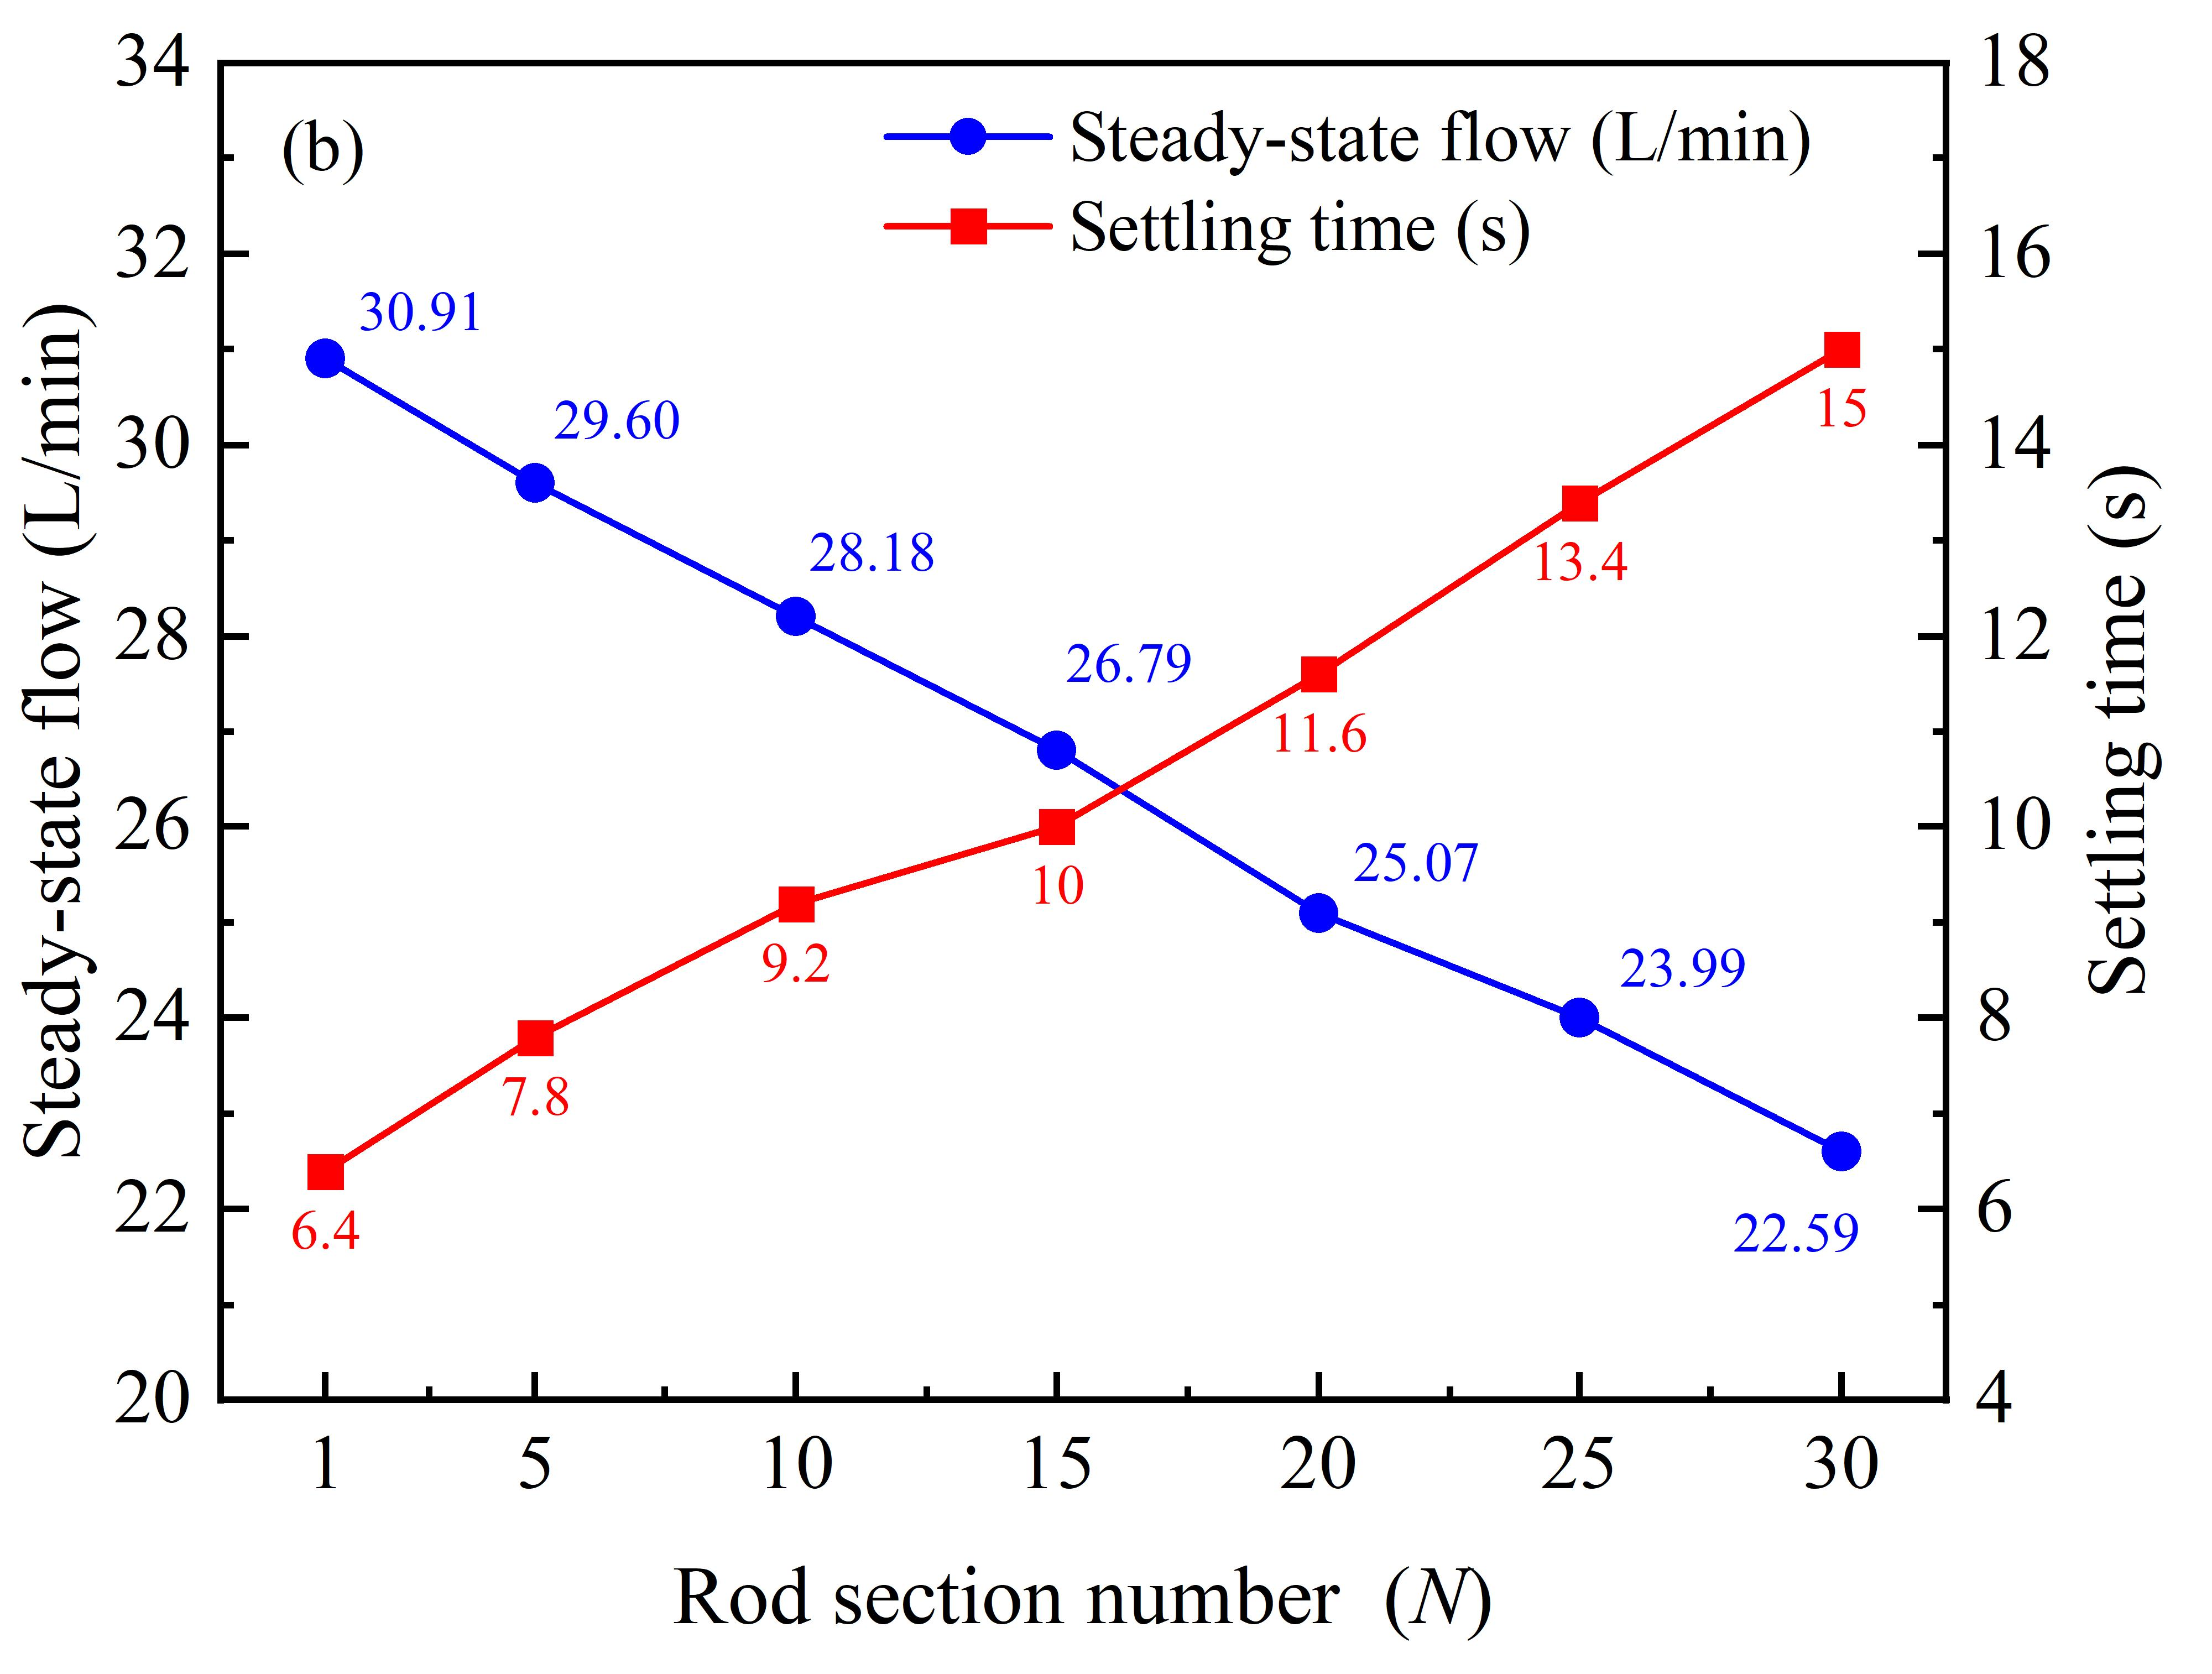
Equations (11)–(13) predict that increasing rod count will raise the required load pressure and prolong settling, particularly at higher rod counts. The pressure and flow-rate responses for different numbers of rod sections are shown in Figure 5, and the steady-state flow rate, steady-state pressure, and settling time are shown in Figure 6.
Figure 5.
Dynamic responses of the hydraulic motor of the lead-screw lifting mechanism for different numbers of rod sections: (a) pressure response; (b) flow-rate response.
Figure 6.
Effects of the number of rod sections on the steady-state responses of the hydraulic motor of the lead-screw lifting mechanism: (a) steady-state pressure and pressure settling time; (b) steady-state flow rate and flow-rate settling time.
In actual operation, each rod section has a mass of approximately 11.66 kg. The figures show that, as rods are successively connected, the steady-state pressure of the hydraulic motor of the lead-screw lifting mechanism increases monotonically overall, and its operating point gradually shifts from the low-pressure region to the high-pressure region. As the number of rod sections increases from 1 to 30, the steady-state pressure rises from 68.13 bar to 96.77 bar, representing a cumulative increase of 42.0% and demonstrating that the additional rod load has a pronounced effect on the motor load pressure. Figure 6 shows that the pressure increases steadily with the number of rod sections and exhibits more pronounced high-pressure characteristics in the heavy-load range. Fundamentally, the increase in rod mass simultaneously raises the load torque reflected to the motor shaft through the lead-screw transmission and the equivalent inertia of the system. Therefore, the load increase caused by rod extension is the dominant factor driving the continuous rise in the operating pressure of the hydraulic motor of the lead-screw lifting mechanism and gradually moves the system into a high-load, high-pressure operating region.
As the number of rod sections increases from 1 to 30, the pressure settling time increases from 5.8 s to 15.5 s, an extension of 9.7 s. For N = 1, 5, 10, 15, 20, 25, and 30, the corresponding pressure settling times are approximately 5.8 s, 6.9 s, 8.1 s, 8.8 s, 12.4 s, 13.9 s, and 15.5 s, respectively, exhibiting an overall nonlinear increase. Meanwhile, as the number of rod sections increases, the steady-state flow rate of the hydraulic motor of the lead-screw lifting mechanism decreases continuously, whereas the flow-rate settling time increases markedly. As the number of rod sections increases from 1 to 30, the steady-state flow rate decreases from 30.91 L/min to 22.59 L/min, a reduction of 26.9%, while the settling time increases from 6.4 s to 15.0 s. The primary reason for this is that the greater load simultaneously increases the motor operating-pressure differential and the equivalent inertia of the system, intensifies leakage at high pressure, and slows the establishment of dynamic equilibrium. When the pump speed and valve-orifice opening remain constant, the higher operating pressure increases pressure-differential-driven leakage through clearances in the pump, motor, and valves, thereby reducing both volumetric efficiency and the effective flow rate reaching the motor. The higher load torque also reduces the motor speed, shifting the system along the combined pump–valve–motor operating characteristic toward the high-pressure, low-flow region. Under the combined effects of increased load and inertia, intensified pressure-differential leakage, and a lower equivalent natural frequency, the system exhibits a high pressure of 96.77 bar and a low flow rate of 22.59 L/min, with a pressure settling time of 15.5 s and a flow-rate settling time of 15.0 s.
To analyze the effects of changes in rod count on system pressure, flow rate, and their settling processes, Figure 7 presents the sensitivity coefficients of pressure, flow rate, pressure settling time, and flow settling time with respect to rod count. Each data point is plotted at the upper endpoint of an adjacent rod-count interval and therefore represents the average proportional sensitivity over that interval. The pressure sensitivity coefficient remains positive throughout, ranging from 0.020 to 0.311, whereas the flow-rate sensitivity coefficient remains negative, ranging from −0.027 to −0.330. This indicates that increasing the rod count raises the required system pressure while reducing the steady-state flow rate. The sensitivity coefficients of both settling times are positive and are generally greater than those of the steady-state responses, demonstrating that rod count has a stronger proportional influence on the transient establishment of pressure and flow than on their final steady-state values. The most pronounced change occurs over the 15–20-rod interval: the pressure settling time increases from 8.8 s to 12.4 s, yielding a sensitivity of 1.192, whereas the corresponding pressure and flow-rate sensitivities are only 0.221 and −0.231, respectively. At higher rod counts, the flow settling time remains highly sensitive, reaching 0.646 and 0.619 over the 20–25-rod and 25–30-rod intervals, respectively. This amplification of the transient response is consistent with the increase in reflected inertia caused by the addition of rods, whereas the gradual rise in steady-state pressure is primarily associated with the increase in load torque.
Figure 7.
Interval logarithmic sensitivity coefficients of pressure, flow rate, and their settling times with respect to rod count.
3.2. Effect of Hydraulic-Hose Length on System Response
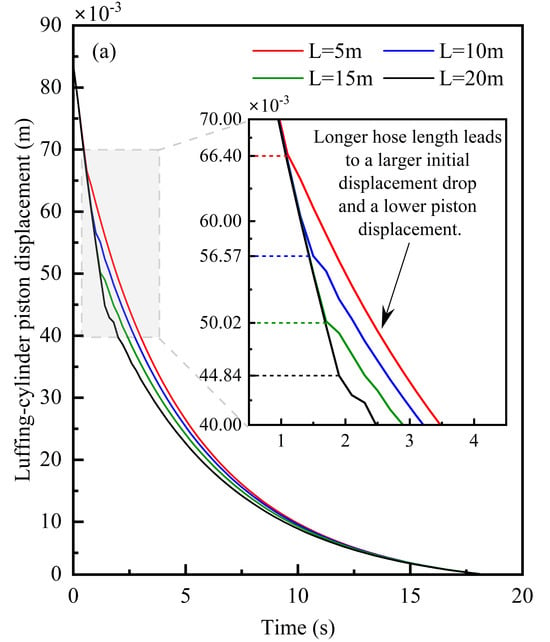
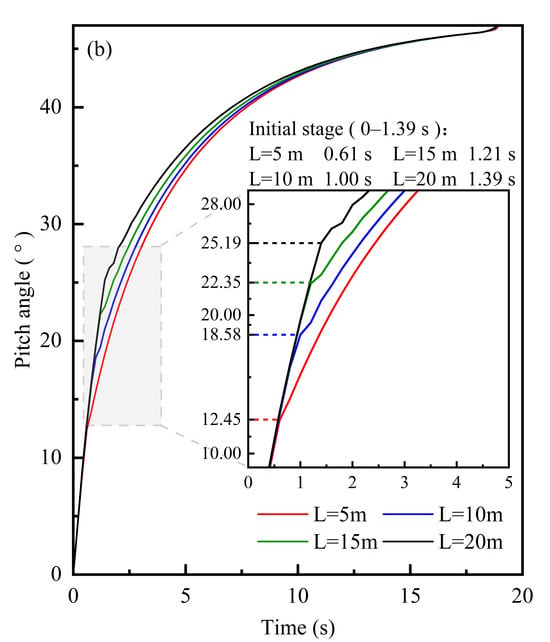
As the cleaning rods are continuously lowered, the effective length L of the hose connected to the luffing mechanism also increases. To clarify how this change affects the motion performance of the mechanism, the piston-displacement and pitch-angle responses of the luffing cylinder were compared for different effective hose lengths.
As shown in Figure 8, for hose lengths of 5, 10, 15, and 20 m, the piston displacement ultimately reaches the same terminal position, while the pitch angle converges to approximately 47° in all cases. This indicates that the effective hose length primarily affects the startup transient without changing the prescribed final control value. For the different hose lengths, the startup stage of the pitch-angle response lasts approximately 0.61 s, 1.00 s, 1.21 s, and 1.39 s, respectively. As the hose length L increases from 5 m to 20 m, the duration of the startup stage increases by approximately 128%. A longer hose increases the volume of hydraulic fluid that must be compressed and permits greater elastic deformation of the hose wall, while also increasing distributed resistance and fluid inertia. Consequently, part of the hydraulic flow through the valve opening is initially used to fill and pressurize the hose, resulting in a more pronounced startup delay in the piston-motion and pitch-angle responses.
Figure 8.
Piston-displacement and pitch-angle responses for different hydraulic-hose lengths: (a) piston-displacement response; (b) pitch-angle response.
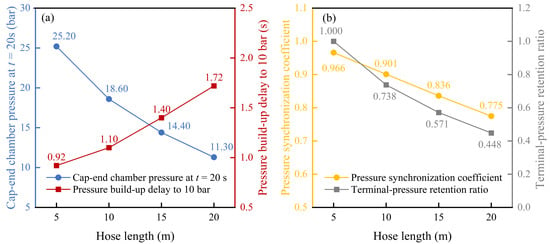
To further reveal the effect of hose length on terminal pressure-transmission characteristics, the pressure build-up process and pressure-holding capability of the cap-end chamber of the luffing cylinder were compared for different hose lengths. Figure 9a further shows that as the hose length increases the terminal pressure in the cap-end chamber continuously attenuates and the pressure build-up process is correspondingly delayed, indicating that long-distance hydraulic-fluid delivery weakens both pressure amplitude and response speed. When L increases from 5 m to 20 m, the terminal pressure decreases by 55.2% and the pressure build-up delay increases by 87.0%. This behavior occurs primarily because increasing the hose length simultaneously increases distributed resistance, liquid-column inertia, and equivalent hydraulic capacitance. A greater proportion of the input flow is therefore used to overcome hose losses, compress the hydraulic fluid, and produce elastic deformation of the hose, which reduces the effective terminal pressure-supply capability and delays the pressure build-up process.
Figure 9.
Pressure-response characteristics of the luffing cylinder for different hydraulic-hose lengths: (a) cap-end chamber pressure and pressure build-up delay; (b) pressure synchronization coefficient and terminal pressure retention ratio.
To further quantify the effect of increasing hose length on the dynamic pressure-tracking relationship, the pressure synchronization coefficient rp is defined as the Pearson correlation coefficient between the pump-source pressure and the terminal cylinder-chamber pressure over the 0–20 s time window, and is calculated as
where m is the number of sampling points within the 0–20 s time window, and the overbar denotes the arithmetic mean of the corresponding pressure series over that window. The pressure synchronization coefficient rp characterizes the degree of temporal consistency between proximal and terminal pressure variations in the hose; a value closer to 1 indicates better synchronization between the pressure responses at the two ends. The terminal pressure retention ratio ηp(L) is defined as the ratio of the terminal pressure under the actual operating condition to that under the 5 m baseline condition and is used to quantify the retention of terminal pressure amplitude relative to the baseline condition. A value closer to 1 indicates less amplitude attenuation during pressure transmission and a greater effective terminal pressure-supply capability.
As shown in Figure 9b, when the hose length increases from 5 m to 20 m, the terminal pressure retention ratio decreases to 0.448, the pressure synchronization coefficient decreases to 0.775, and the pressure build-up delay increases to 1.72 s. These results indicate that the hydraulic system exhibits pronounced pressure attenuation, response lag, and reduced synchronization. As the hose length increases, friction between the hydraulic fluid and the hose wall accumulates, increasing the distributed pressure loss and thereby reducing the effective pressure transmitted to the actuator. At the same time, the greater liquid-column mass increases fluid inertia, slowing the propagation and recovery of pressure disturbances. The volume of hydraulic fluid contained in the hose and the elastic deformation of the hose increase concurrently, increasing the equivalent hydraulic capacitance of the system. Consequently, during startup, more proportion of the inlet flow is temporarily diverted to fluid compression and hose expansion rather than being immediately available to drive the hydraulic cylinder.
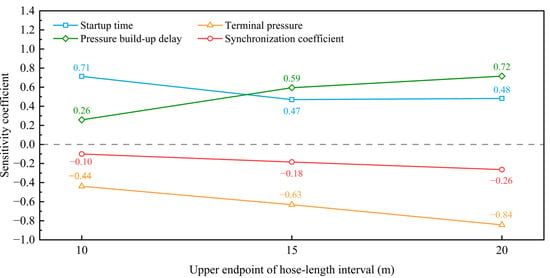
Figure 10 compares the interval logarithmic sensitivity coefficients of four hydraulic responses with respect to hose length. The data points plotted at 10, 15, and 20 m represent the average sensitivity coefficients over the adjacent intervals of 5–10, 10–15, and 15–20 m, respectively. The startup-time sensitivity coefficient remains positive, with values of 0.71, 0.47, and 0.48, indicating that increasing the hose length consistently delays system startup. The sensitivity coefficient of the pressure build-up delay increases from 0.26 to 0.59 and 0.72, demonstrating that the pressure-transmission process becomes progressively more sensitive to hose length as the hose is extended. In contrast, the terminal-pressure sensitivity coefficient decreases from −0.44 to −0.63 and −0.84, indicating an increasingly pronounced negative effect. The sensitivity coefficient of the synchronization coefficient also decreases from −0.10 to −0.18 and −0.26. These results show that, as the hose length increases, its dominant effects gradually shift toward a longer pressure build-up delay and a lower terminal pressure, whereas the deterioration in synchronization is comparatively moderate. These trends are consistent with the theoretical expectation that hydraulic capacitance, fluid inertia, and distributed flow resistance increase jointly in a longer hose, thereby driving the observed dynamic response.
Figure 10.
Interval logarithmic sensitivity coefficients of startup time, terminal pressure, pressure build-up delay, and synchronization coefficient with respect to hose length.
3.3. Effects of the Valve-Group Actuation Interval on System Response
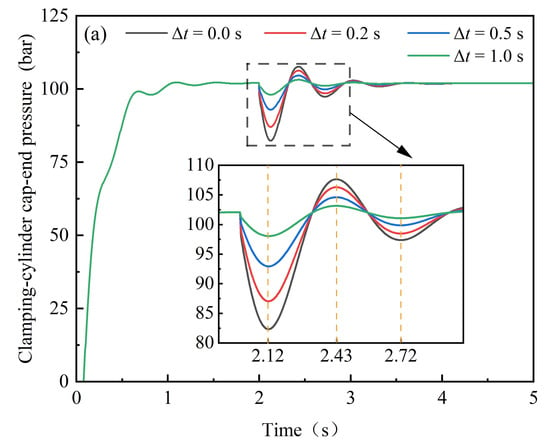
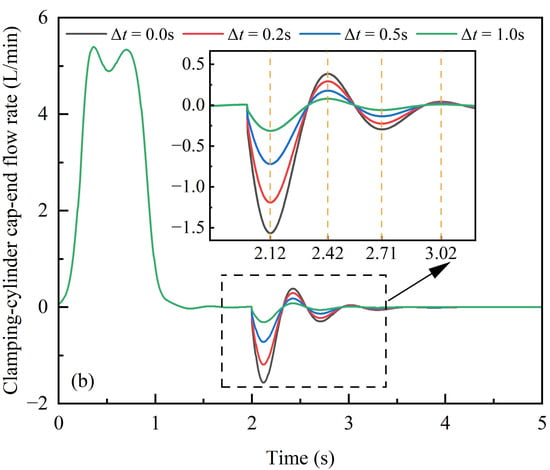
To investigate the effects of the valve-group actuation interval on the dynamic stability of the branches under shared-pump hydraulic supply to multiple actuators, the actuation interval Δt between adjacent valve groups was set to 0, 0.2, 0.5, and 1.0 s while the pump-source parameters, valve-orifice opening, and load conditions were held constant, and the pressure and flow-rate responses of the clamping and luffing branches were compared. Figure 11 shows that, after pressure build-up, the cap-end pressure of the clamping cylinder stabilized at approximately 101 bar. After the actuator stopped moving, the branch flow rate gradually returned to 0 L/min, and the branch entered a pressure-holding state through the locking element.
Figure 11.
Dynamic responses of the clamping branch at different valve-group actuation intervals: (a) cap-end pressure of the clamping cylinder; (b) cap-end flow rate of the clamping cylinder.
However, when another branch was activated, the additional transient flow demand disrupted the original equilibrium and redistributed the supplied flow among the branches. Because the pump’s instantaneous supply capacity was limited and flow was required for valve-orifice opening, line filling, and fluid compression, the pressure-holding branch briefly released some of its compressed fluid, resulting in a pressure drop and transient reverse flow.
The composite disturbance attenuation rate is defined as
where qc,min and ql,min are the minimum flow rates of the clamping and luffing branches, respectively; negative values indicate a reverse flow rate. A larger value of indicates that staggered actuation more effectively suppresses transient disturbances in the shared-pump branches.
When the two valve groups were actuated simultaneously, i.e., Δt = 0 s, the transient flow demands of the two branches overlapped extensively in time, producing the greatest mismatch between supply capacity and total demand. The cap-end pressure of the clamping cylinder consequently fell from approximately 101 bar to approximately 82 bar, a decrease of nearly 19%, and a reverse flow rate of approximately −1.6 L/min occurred. After the hydraulic supply was re-established, the branch pressure exhibited an overshoot in the opposite direction and returned to a steady state after a period of damped oscillation. This process indicates that the hydraulic elastic energy stored in the branch was released first to compensate for the transient flow demand of the newly activated branch, after which replenishment from the pump source rebuilt the pressure, producing the continuous dynamic sequence of “pressure drop–reverse flow–pressure overshoot–oscillation decay.” As the valve-group actuation interval Δt gradually increased, the startup flow peak and pressure fluctuation of the first branch partially decayed before the second branch was activated, staggering the flow peaks of the two branches. Consequently, the pressure trough of the clamping cylinder rose progressively, while both the peak reverse flow rate and the amplitude of the recovery oscillation decreased markedly.
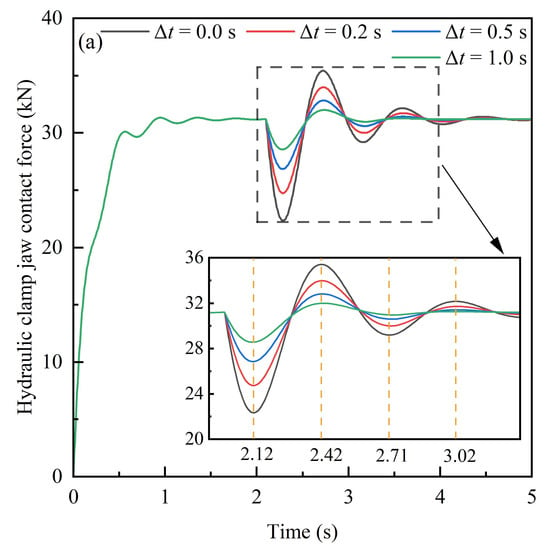
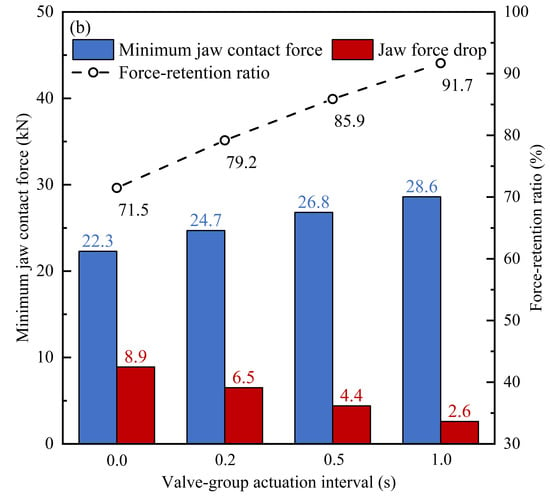
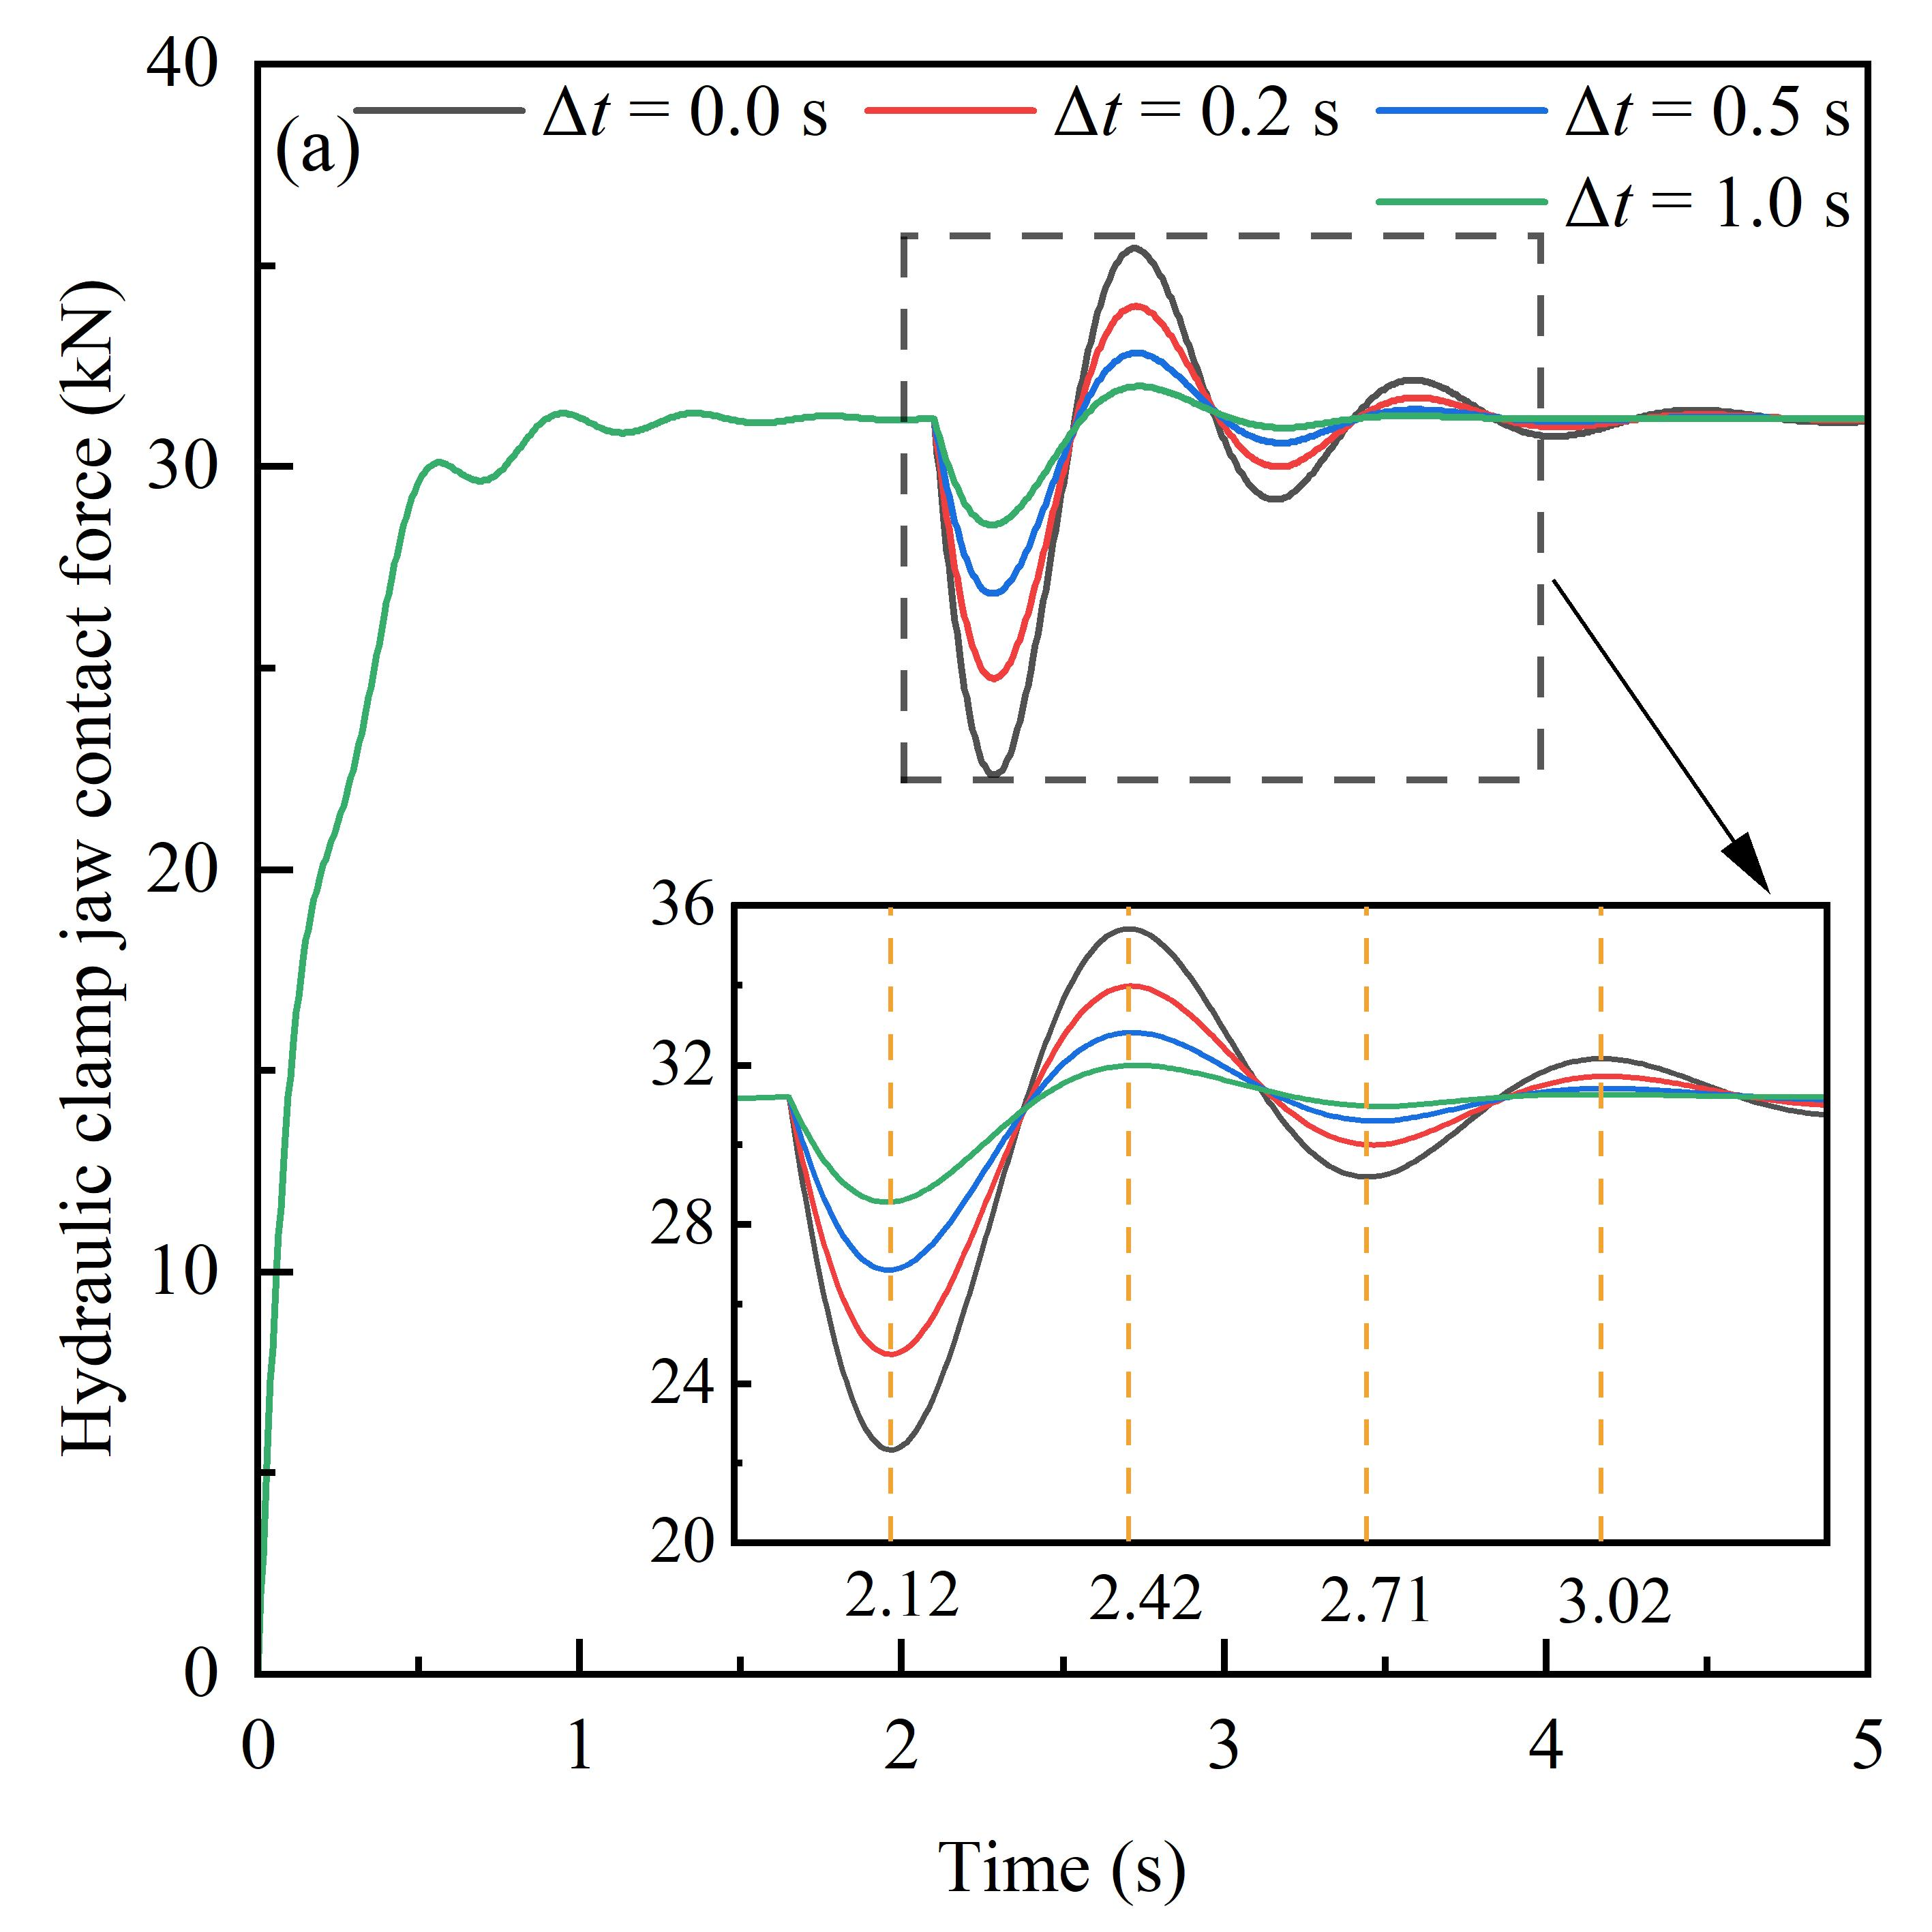
The results in Figure 12 shows that the valve-group actuation interval not only altered the amplitude of pressure fluctuations in the clamping branch but also directly affected the ability to retain jaw contact force. During steady system operation, the jaw contact force was approximately 31.2 kN. When another actuator branch was activated, transient flow in the system with shared-pump hydraulic supply was redistributed. Because the clamping cylinder, branch line, and hydraulic fluid all exhibit a degree of compliance, the original pressure in the clamping branch could not be maintained immediately; the elastic energy stored in the hydraulic cylinder was therefore released, manifesting as a decrease in contact force through the jaw–rod contact pair. Under simultaneous valve-group actuation (Δt = 0 s), the transient flow peaks of the two branches overlapped extensively, and the disturbance was most severe: the minimum contact force fell to 22.3 kN, the contact-force drop reached 8.9 kN, the retention ratio was only 71.5%, and clamping stability was poorest. As the actuation interval increased, the transient flow demands of the two branches became progressively staggered, allowing the pump-source pressure and supply capacity of the clamping branch to recover before the second valve group was actuated. The contact-force trough therefore rose, and the oscillation amplitude decreased markedly. When Δt increased from 0 to 1.0 s, the minimum contact force rose from 22.3 kN to 28.6 kN, the contact-force drop decreased from 8.9 kN to 2.6 kN, a reduction of 70.8%, and the contact-force retention ratio increased from 71.5% to 91.7%. At Δt = 0.5 s, the minimum contact force was 26.8 kN, the drop was 4.4 kN, and the retention ratio reached 85.9%; these values indicate that clamping-force attenuation caused by branch switching was substantially suppressed while avoiding the adverse effect of an excessively long actuation interval on the continuity of combined operations.
Figure 12.
Contact-force response of the hydraulic clamp jaws at different valve-group actuation intervals: (a) dynamic response of jaw contact force; (b) minimum contact force, contact-force drop, and retention ratio.
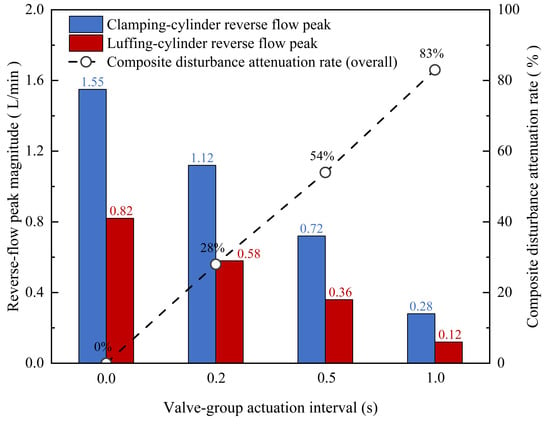
As shown in Figure 13, when the valve-group actuation interval Δt increased from 0 to 1.0 s, the peak reverse flow rate in the clamping branch decreased from 1.55 L/min to 0.28 L/min, while that in the luffing branch decreased from 0.82 L/min to 0.12 L/min; the composite disturbance attenuation rate increased from 0 to 83%.
Figure 13.
Effects of the valve-group actuation interval on peak reverse flow rates and disturbance attenuation characteristics of the hydraulic branches.
In summary, a complete rod-connection cycle sequentially comprises the first clamping action, lowering, the second clamping action, release, lifting, and threaded connection, forming six consecutive control commands and five internal intervals between adjacent valve-group commands. During continuous operation, an additional interval occurs between the final command of one cycle and the first command of the next cycle. Among the investigated settings, the system disturbance was minimized at Δt = 1.0 s. Although this setting further suppressed the pressure and flow disturbances and increased the clamping-force retention ratio to approximately 91.7%, it cumulatively increased the operating time by approximately 179–239 s over 30–40 rod-connection cycles. At Δt = 0.5 s, the peak reverse flow rates in the clamping and luffing branches decreased to approximately 0.72 and 0.36 L/min, respectively. Consequently, the sum of the peak reverse flow rates decreased from 2.37 to 1.08 L/min, corresponding to a composite disturbance attenuation rate of approximately 54%, while the clamping-force retention ratio increased from 71.5% to 85.9%. This setting therefore substantially attenuated the coupled pressure–flow disturbance without incurring the larger cumulative time penalty associated with the 1.0 s interval. Under the current pump-source and valve-orifice parameters, 0.5 s therefore provides a model-specific compromise between hydraulic stability and continuity of operation under the investigated conditions. With this setting, the subsequent valve group is actuated after a larger portion of the preceding branch transient has decayed, improving the modeled response under the investigated load conditions.
3.4. Effect of the Hose-Coiling State on Pipeline Pressure Loss
During operation of the coal-bunker cleaning device, the hydraulic hose wound around the winch was progressively unwound as rods were connected and lowered one by one, and its deployed length changed with the operating position. To accurately describe the effect of the hose-coiling condition encountered during coal-bunker cleaning on hydraulic-system pressure loss, this study used the classical Darcy–Weisbach equation together with studies of pressure loss in coiled and helical pipes [18,20,28] to develop a multiparameter pressure-loss model [22] incorporating frictional pressure loss, local pressure loss, and coiling-induced additional pressure loss. The frictional loss is determined by hose length, inner diameter, flow velocity, and friction factor, whereas the coiling-induced additional loss represents the additional dissipation caused by curvature, interlayer constraints, and secondary flow. Accordingly, the pressure-loss components of the hydraulic hose can be expressed as follows:
where ΔPf is the frictional pressure loss; ΔPl is the local pressure loss; ΔPc is the coiling-induced additional pressure loss; v is the mean flow velocity; ρ is the hydraulic-oil density; f is the friction factor; D is the inner diameter of the hose; Leq is the equivalent hose length; ζ is the local resistance coefficient for components such as elbows and fittings; and Kb is the hose-bending correction coefficient. It is determined by first calculating the Dean number from the instantaneous Reynolds number, hose inner diameter, and reel radius, and then comparing the Darcy friction factor of the coiled hose, calculated using the Mishra–Gupta correlation for laminar flow in curved pipes, with that of the straight hose section at the same flow rate [31,32]. Here, μ is the dynamic viscosity; Re is the Reynolds number; R is the reel radius; De is the Dean number; fs and fc are the Darcy friction factors for the straight and coiled hose, respectively; N is the modeled equivalent coiling state; and L0 is the remaining straight hose length. Under the stated fixed-total-length condition, L0 + 2πRN = 30 m for each modeled coiling state.
The Mishra–Gupta correlation for laminar flow in curved pipes is
The total system pressure drop can then be expressed as
The simulation employed ISO VG 46 hydraulic oil at 25 °C, with a density of 865 kg/m3 and a dynamic viscosity of 85 mPa·s. The coiled main-supply hose had an inner diameter of 16.2 mm. For trend comparison, a constant-pressure pump source with a flow-rate range of 0–40 L/min was adopted. The reel-drum radius was set to 0.30 m, and the total hose length was 30 m. The simulation model calculated the cross-sectional mean velocity and Reynolds number in real time based on the instantaneous flow rate, hose cross-sectional area, fluid density, dynamic viscosity, and hose inner diameter. Within the investigated flow-rate range, the maximum Reynolds number was approximately 533; therefore, all nonzero-flow conditions were treated as laminar flow. The Darcy friction factor for the straight hose section was calculated using the classical laminar-flow relationship and was approximately 0.120 at the maximum flow rate.
Based on the above parameters and calculation method, a co-simulation was conducted using an external MATLAB calculation module and the AMESim hydraulic-system model. AMESim output the instantaneous line flow rate to MATLAB. The MATLAB module then calculated the frictional pressure loss along the straight hose section and the additional pressure loss induced by hose coiling in real time according to Equations (16)–(24), and fed the calculated results back into the hydraulic model. The local pressure losses associated with bends and other inline components were calculated directly within the AMESim model.
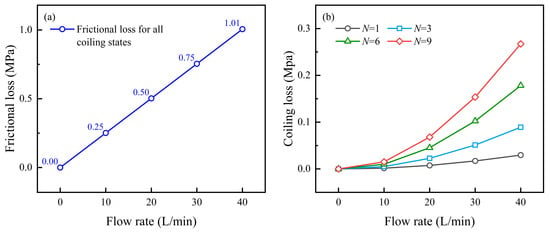
As shown in Figure 14, the frictional loss is common to all four equivalent coiling-layer states, whereas the coiling-induced loss increases with both flow rate and N. At 22.59 L/min, the frictional loss was approximately 0.568 MPa, and the coiling-induced losses for N = 1, 3, 6, and 9 were approximately 0.0097, 0.0291, 0.0582, and 0.0874 MPa, respectively.
Figure 14.
Pressure-loss components calculated over the 0–40 L/min flow-rate range: (a) frictional loss common to all equivalent coiling-layer states; (b) coiling-induced loss for N = 1, 3, 6, and 9.
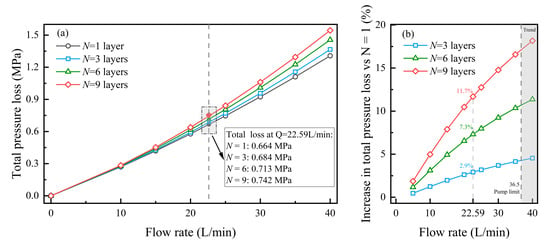
The total pressure loss shown in Figure 15 was calculated for the complete oil-supply path from the pump outlet to the actuator inlet. This path includes the straight hose from the pump to the reel, the reel-mounted hose, the rotary joint and other connectors, local bends, the valve group, and the downstream hose leading to the actuator. Figure 15 further shows that the total pressure loss increased with flow rate for every equivalent coiling-layer state, while the separation among the total-loss curves was produced by the coiling-induced term. At 22.59 L/min, the calculated total pressure losses for N = 1, 3, 6, and 9 were 0.664, 0.684, 0.713, and 0.742 MPa, respectively. The loss for the nine-layer state was therefore approximately 11.7% higher than that for the one-layer state. At this operating point, the frictional and local losses remained common to all four states. The difference among equivalent coiling-layer states becomes more visible as flow rate rises. High flow should be avoided when the hose is in a more tightly coiled state.
Figure 15.
Variation in total pipeline pressure drop with flow rate for different numbers of coiling layers: (a) total pressure loss for N = 1, 3, 6, and 9; (b) percentage increase in total pressure loss relative to N = 1.
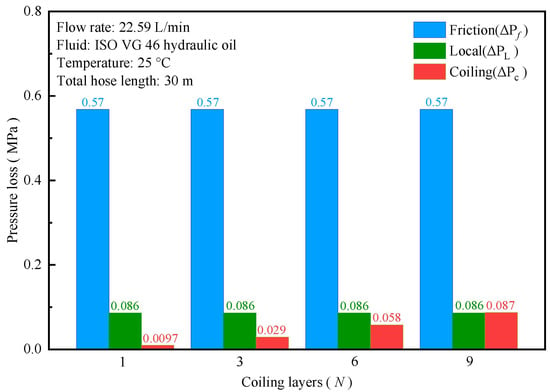
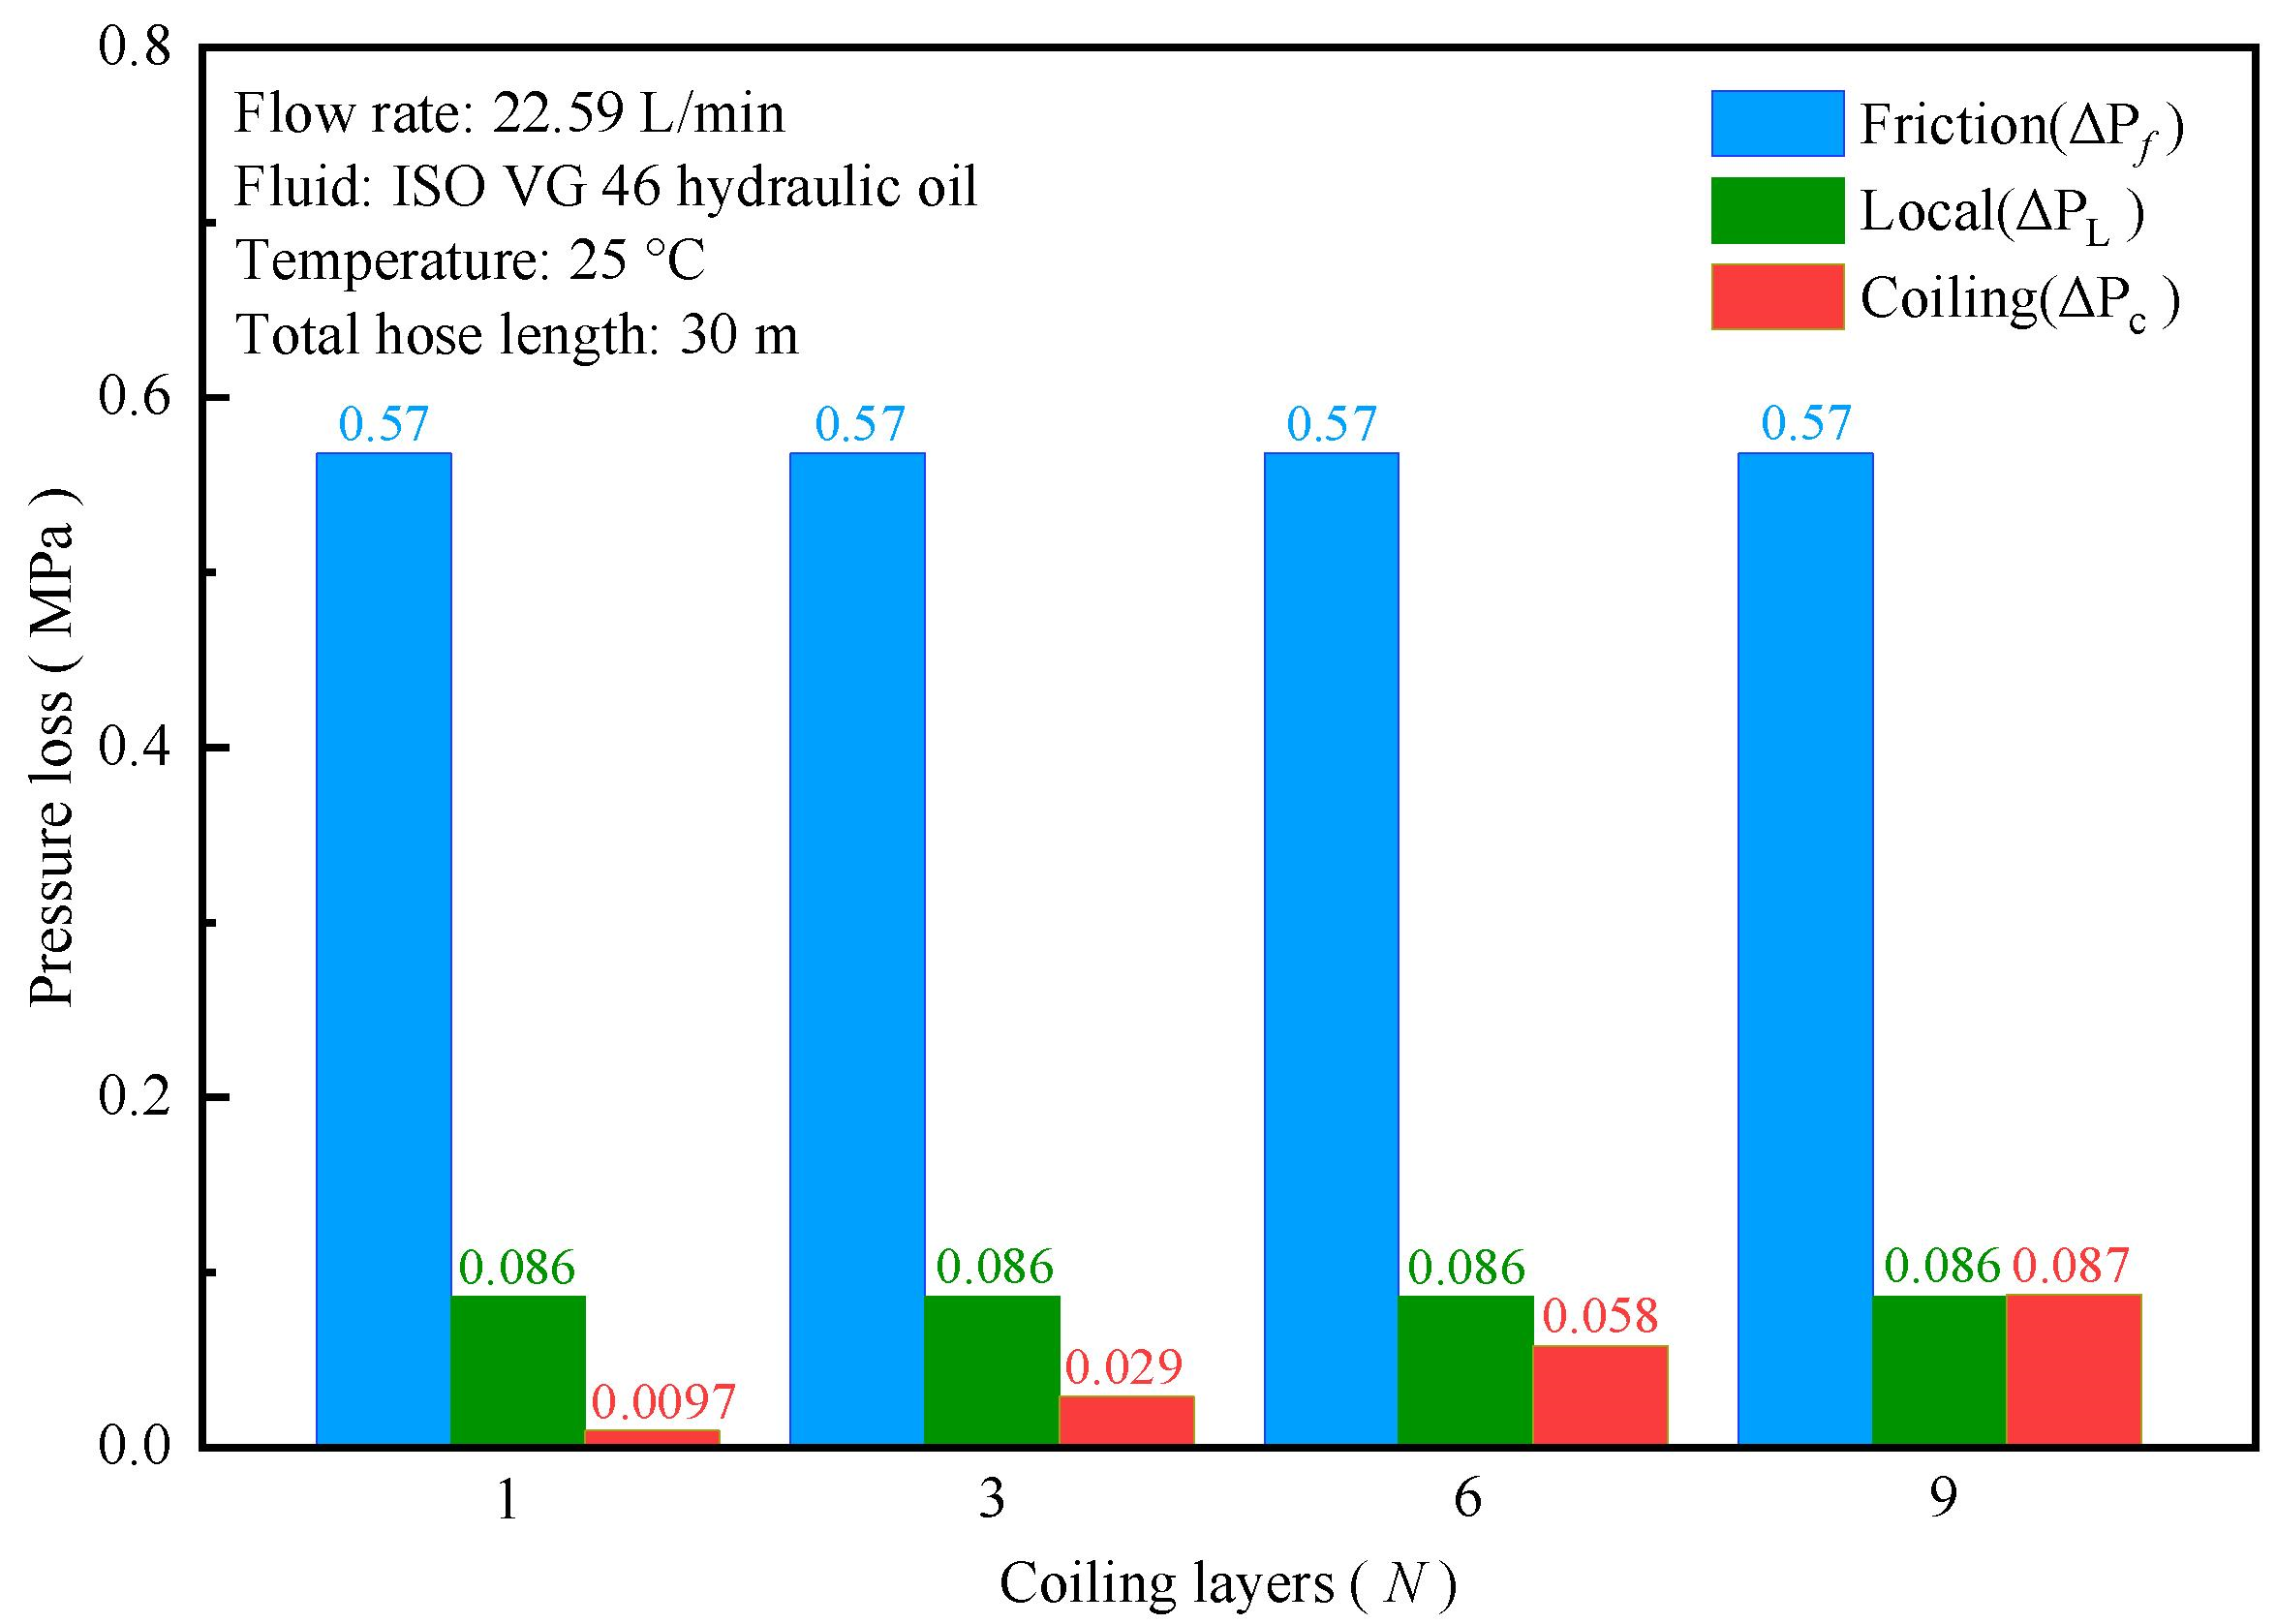
Figure 16 separates the three pressure-loss components at 22.59 L/min. The common frictional loss was approximately 0.568 MPa, and the local-loss output obtained directly from AMESim was approximately 0.086 MPa. The coiling-induced loss increased from approximately 0.0097 MPa at N = 1 to 0.0874 MPa at N = 9. Thus, ΔPt = ΔPf + ΔPl + ΔPc gives 0.664, 0.684, 0.713, and 0.742 MPa for N = 1, 3, 6, and 9, respectively. Frictional loss accounted for approximately 76.6–85.5% of the total and remained the dominant component, whereas the coiling-induced share increased from approximately 1.5% to 11.8%.
Figure 16.
Pressure-loss components at 22.59 L/min for different equivalent coiling-layer states.
3.5. Sensitivity and Dominant-Mechanism Results
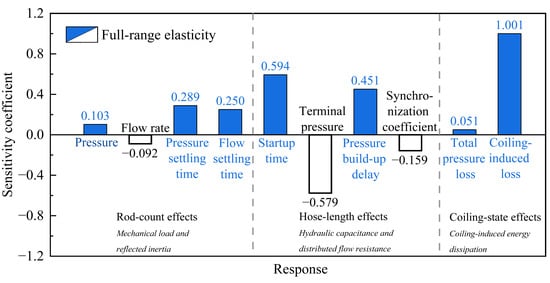
Building on the preceding analyses of the independent effects of each parameter, this section converts the existing numerical results into a unified dimensionless framework to identify the physical mechanisms governing different types of system response. By examining the available results at both the full parameter-range level and the adjacent parameter-interval level, the overall response trends can be distinguished from localized amplification of sensitivity. Because the valve-group actuation interval includes a zero-valued baseline condition, its influence is evaluated using the normalized disturbance attenuation rate and clamping-force retention ratio. The resulting quantitative indicators are then associated with four physically meaningful pathways: mechanical load and reflected inertia; hydraulic capacitance and distributed flow resistance; the temporal overlap of flow demands among different branches; and additional energy dissipation induced by hose coiling. Within the ranges covered by the current model and parameters, this analysis therefore provides a quantitative basis for identifying the direction of response variation, the relative degree of sensitivity, and the principal mechanisms governing the system dynamics. The comparative results for the parameters examined in the preceding analyses are presented in Figure 17.
Figure 17.
Full-range signed sensitivity coefficients of system responses to rod count, hose length, and coiling-layer state.
In Figure 17, positive and negative values indicate that the response increases or decreases with an increase in the corresponding parameter, respectively, while a larger absolute value indicates a higher degree of sensitivity. The first four responses correspond to an increase in rod count from 1 to 30. The sensitivity coefficients of pressure and flow rate are 0.103 and −0.092, respectively, whereas the corresponding coefficients for pressure settling time and flow-rate settling time reach 0.289 and 0.250, respectively. Therefore, compared with the steady-state pressure and flow rate, rod count has a stronger proportional influence on the transient settling process, which is consistent with the theoretical expectation that adding rods increases the reflected inertia.
The following four responses correspond to an increase in hose length from 5 m to 20 m. The sensitivity coefficients of startup time and pressure build-up delay are 0.594 and 0.451, respectively, whereas the corresponding coefficients for terminal pressure and the synchronization coefficient are approximately −0.579 and −0.159, respectively. These results demonstrate that hose length primarily affects system startup and pressure transmission through the combined effects of increased hydraulic capacitance and distributed flow resistance.
For the equivalent coiling-layer state, the sensitivity coefficient of the coiling-induced additional pressure loss is approximately unity (1.001), indicating that it increases nearly in proportion to the equivalent coiling-layer state. In contrast, the sensitivity coefficient of the total pressure loss is only 0.051. Thus, although the equivalent coiling-layer state strongly affects the coiling-induced additional loss, its effect on the total pressure loss is comparatively limited, and the total pressure loss remains dominated by distributed frictional loss.
4. Discussion
The ADAMS–AMESim mechanical–hydraulic coupling model showed good numerical consistency with the standalone hydraulic model, with major steady-state deviations below 3% and a hydraulic-motor torque RMSE of 0.36 N·m, indicating its suitability for comparative parameter analysis.
The results show that progressive rod connection increases load torque and equivalent inertia, shifting the hydraulic motor toward a high-pressure and low-flow operating region and prolonging the settling process. Increasing hose length weakens remote pressure transmission and dynamic synchronization by increasing distributed flow resistance, fluid-column inertia, compressible oil volume, and hose-wall compliance. Under common-pump supply conditions, simultaneous valve actuation produces overlapping transient flow demands, leading to pressure release, reverse flow, and reduced hydraulic-cylinder force. Increasing the valve actuation interval mitigates these disturbances. The dimensionless sensitivity comparison further shows that transient settling is more sensitive to rod count than steady-state pressure and flow rate, whereas startup time and terminal pressure are the most sensitive hose-length responses. Under the present conditions, Δt = 0.5 s reduces the peak branch flow fluctuation by approximately 54% and increases the clamping-force retention ratio from 71.5% to 85.9%. At 22.59 L/min, the frictional and local losses were approximately 0.568 and 0.086 MPa, respectively, and were common to all equivalent coiling-layer states, whereas the coiling-induced term increased smoothly from approximately 0.0097 MPa at N = 1 to 0.0874 MPa at N = 9. The corresponding total pressure loss increased from 0.664 to 0.742 MPa (approximately 11.7%). The key findings and corresponding engineering recommendations are summarized in Table 3.
Oil-temperature variation can affect hydraulic-oil viscosity, pressure loss, leakage, and transient response. A uniform reference temperature of 25 °C was adopted because the device operates in a belt roadway with relatively limited seasonal temperature variation, and a single continuous operation usually lasts less than 60 min. Therefore, the conclusions mainly apply to short-duration operation under stable ambient temperature and limited oil-temperature rise. The constant torque-efficiency assumption and the absence of experimental validation also limit the accuracy of absolute predictions. Future work will include experimental calibration and further investigation of operating-condition-dependent efficiency, oil-temperature variation, hose deformation, and leakage.
Table 3.
Key findings and engineering implications.
5. Conclusions
An ADAMS–AMESim mechanical–hydraulic co-simulation model of a ground coal-bunker cleaning device was established, and a coiled-hose pressure-drop model under a fixed total hose length was implemented through a MATLAB variable-resistance module. The main conclusions are as follows.
- (1)
- During rod connection, the hydraulic motor of the lead-screw lifting mechanism shifted toward high-pressure, low-flow-rate, and slow-response operation. Increasing the number of rod sections from 1 to 30 raised the steady-state pressure from 68.13 to 96.77 bar (42.0%), reduced the steady-state flow rate by 26.9%, and increased the pressure settling time from 5.8 to 15.5 s (167.2%). Increased rod mass raised the load torque and equivalent rotational inertia reflected at the motor shaft, thereby increasing the required driving pressure differential and pressure-differential leakage while decreasing the natural frequency. These effects weakened the system’s speed-holding capability and transient response performance.
- (2)
- Increasing the hydraulic-hose length weakened the transient response and terminal pressure-supply capability of the luffing mechanism but minimally affected its final pose when supply capacity remained sufficient. As the effective hydraulic-hose length increased from 5 to 20 m, the luffing-cylinder startup phase increased from 0.61 to 1.39 s (127.9%), cylinder pressure decreased from 25.20 to 11.30 bar (55.2%), pressure build-up delay increased from 0.92 to 1.72 s, and the pressure synchronization coefficient decreased from 0.966 to 0.775. Increased frictional loss, fluid-column inertia, fluid compression, and hose elastic deformation caused terminal pressure attenuation, slower pressure build-up, and reduced response capability.
- (3)
- Simultaneous actuation of multiple actuators reduced the cap-end pressure of the clamping cylinder from approximately 101 to 82 bar (nearly 19%) and induced reverse flow of approximately −1.6 L/min. At a valve-group actuation interval of 0.5 s, the peak reverse flow rates in the clamping and luffing branches decreased to approximately 0.72 and 0.36 L/min, respectively, and the composite disturbance attenuation rate reached approximately 54%. This interval provided a favorable balance between system stability and continuity of motion under the current system parameters.
- (4)
- With a fixed total line length of 30 m, an oil temperature of 25 °C, and ISO VG 46 hydraulic oil, the 0–40 L/min pipeline-submodel sweep showed that frictional loss remained the dominant component, while coiling-induced loss increased with flow rate and the equivalent coiling-layer state. At 22.59 L/min, the frictional and local losses were approximately 0.568 and 0.086 MPa, respectively; the coiling-induced loss increased from 0.0097 MPa at N = 1 to 0.0874 MPa at N = 9, giving total pressure losses of 0.664–0.742 MPa and an increase of approximately 11.7% from N = 1 to N = 9.
- (5)
- Sensitivity analysis showed that rod count affects pressure and flow settling times more strongly (0.289 and 0.250) than steady-state pressure and flow rate (0.103 and −0.092), indicating that reflected inertia dominates the transient response, while load torque mainly governs the steady-state behavior. Hose length strongly affects startup time and terminal pressure (0.594 and −0.579), whereas hose coiling mainly increases the additional curvature-induced loss (1.001) and has little influence on the total pressure loss (0.051), which remains dominated by distributed friction. These results identify the dominant physical mechanisms governing different system responses within the ranges covered by the current model and parameters.
Overall, these results provide a theoretical basis and practical engineering guidance for optimizing the actuation timing, hose layout, and operating strategy of the cleaning device.
Author Contributions
J.W.: Conceptualization, Methodology, Investigation, Data Curation, Formal Analysis, Visualization, Writing—Original Draft. X.Z.: Supervision, Project Administration, Funding Acquisition, Conceptualization, Writing—Review and Editing. H.G.: Methodology, Validation, Writing—Review and Editing. All authors have read and agreed to the published version of the manuscript.
Funding
This study was supported by the Shandong Key Laboratory of Collaborative Mining Technology for Intelligent Mine Equipment (PKL2024F14).
Data Availability Statement
The data that support the findings of this study are available on request from the corresponding author.
Conflicts of Interest
The authors declare that they have no known competing financial interests or personal relationships that could have appeared to influence the work reported in this paper.
References
- Zhu, D.; Ji, X.; Huo, Y.; Wang, Z.; Yu, B.; Wang, D. Numerical Investigation of Particles Flow Pattern and Pressure Distribution of Coal Bunker. J. Geophys. Eng. 2023, 20, 841–853. [Google Scholar] [CrossRef] [Scilit]
- Jiang, C.; Wang, L.; Pan, Z.; Guo, J.; Wang, S. Study on the Adhesion Properties of Raw Coal and Adhesive Clogging Characteristics of Underground Coal Bunkers. Appl. Sci. 2025, 15, 684. [Google Scholar] [CrossRef] [Scilit]
- Shafaei, S.M.; Mousazadeh, H. Development of a Mobile Robot for Safe Mechanical Evacuation of Hazardous Bulk Materials in Industrial Confined Spaces. J. Field Robot. 2022, 39, 218–231. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Shen, T.; Tan, C.; Fu, J.; Guo, S. Research Status, Critical Technologies, and Development Trends of Hydraulic Pressure Pulsation Attenuator. Chin. J. Mech. Eng. 2021, 34, 14. [Google Scholar] [CrossRef] [Scilit]
- Zhang, K.; Zhang, J.; Gan, M.; Zong, H.; Wang, X.; Huang, H.; Su, Q.; Xu, B. Modeling and Parameter Sensitivity Analysis of Valve-Controlled Helical Hydraulic Rotary Actuator System. Chin. J. Mech. Eng. 2022, 35, 66. [Google Scholar] [CrossRef] [Scilit]
- Kittisares, S.; Hirota, Y.; Nabae, H.; Suzumori, K. Open-Looped Pressure and Volume Control of Multi-Degree-of-Freedom Hydraulic Systems. Mechatronics 2023, 95, 103068. [Google Scholar] [CrossRef] [Scilit]
- Cheng, M.; Sun, B.; Ding, R.; Xu, B. A Multi-Mode Electronic Load Sensing Control Scheme with Power Limitation and Pressure Cut-off for Mobile Machinery. Chin. J. Mech. Eng. 2023, 36, 29. [Google Scholar] [CrossRef] [Scilit]
- Lin, Z.; Lin, Z.; Wang, F.; Xu, B. A Series Electric Hybrid Wheel Loader Powertrain with Independent Electric Load-Sensing System. Energy 2024, 286, 129497. [Google Scholar] [CrossRef] [Scilit]
- Li, L.; Chen, H.; Jin, R.; Xu, Y.; Liu, Q.; Li, G.; Huang, H. Independent Metering-Based Leveling System with Multi-Actuator for Energy Saving: Modeling, Control, and Application on Large-Size Forming Equipment. Energy Convers. Manag. 2024, 302, 118119. [Google Scholar] [CrossRef] [Scilit]
- Fresia, P.; Rundo, M.; Padovani, D.; Altare, G. Combined Speed Control and Centralized Power Supply for Hybrid Energy-Efficient Mobile Hydraulics. Autom. Constr. 2022, 140, 104337. [Google Scholar] [CrossRef] [Scilit]
- Wang, F.; Wu, J.; Lin, Z.; Zhang, H.; Xu, B. A Power-Sharing Electro-Hydraulic Actuator System to Downsize Electric Motors for Electric Mobile Machines. Energy 2023, 284, 129343. [Google Scholar] [CrossRef] [Scilit]
- Padovani, D.; Dimitriou, P.; Minav, T. Challenges and Solutions for Designing Energy-Efficient and Low-Pollutant Machines in Off-Road Hydraulics. Energy Convers. Manag. X 2024, 21, 100526. [Google Scholar] [CrossRef] [Scilit]
- Mu, H.; Cheng, M.; Tang, X.; Ding, R.; Ma, W. A Hybrid Distributed-Centralized Load Sensing System for Efficiency Improvement of Electrified Construction Machinery. Energy 2025, 314, 134123. [Google Scholar] [CrossRef] [Scilit]
- Kadar, F.; Stepan, G. Nonlinear Dynamics and Safety Aspects of Pressure Relief Valves. Nonlinear Dyn. 2023, 111, 12017–12032. [Google Scholar] [CrossRef] [Scilit]
- Urbanowicz, K.; Haluch, I.; Bergant, A.; Deptuła, A.; Śliwiński, P. Initial Investigation of Wave Interactions During Simultaneous Valve Closures in Hydraulic Piping Systems. Water Resour. Manag. 2023, 37, 5105–5125. [Google Scholar] [CrossRef] [Scilit]
- Guo, X.; Deng, J.; Cao, Z. Study on the Propagation Characteristics of Pressure Wave Generated by Mechanical Shock in Leaking Pipelines. Process Saf. Environ. Prot. 2022, 164, 706–714. [Google Scholar] [CrossRef] [Scilit]
- Lu, P.; Sheng, X.; Gao, Y.; Wang, R. Influence of Shear Effects on the Characteristics of Axisymmetric Wave Propagation in a Buried Fluid-Filled Pipe. Chin. J. Mech. Eng. 2022, 35, 74. [Google Scholar] [CrossRef] [Scilit]
- Andrade, D.M.; Bastos De Freitas Rachid, F.; Tijsseling, A.S. An Analysis of Fluid–Structure Interaction Coupling Mechanisms in Liquid-Filled Viscoelastic Pipes Subject to Fast Transients. J. Fluids Struct. 2023, 121, 103924. [Google Scholar] [CrossRef] [Scilit]
- Klaerner, M.; Kroll, L.; Metzler, D.; Eberl, R.; De Lima, L.Z.; Kloft, P.; Kusserow, T.; Sander, M.; Thielecke, F. Reduction of Fluid Noise in Modern Aircraft Hydraulics by Integrated Broadband Attenuators. CEAS Aeronaut. J. 2025, 16, 417–425. [Google Scholar] [CrossRef] [Scilit]
- Oliveira, B.R.; Leal, B.C.; Pereira Filho, L.; Borges, R.F.D.O.; Paraíso, E.D.C.H.; Magalhães, S.D.C.; Rocha, J.M.; Calçada, L.A.; Scheid, C.M. A Model to Calculate the Pressure Loss of Newtonian and Non-Newtonian Fluids Flow in Coiled Tubing Operations. J. Pet. Sci. Eng. 2021, 204, 108640. [Google Scholar] [CrossRef] [Scilit]
- Wei, S.; Sun, Y.; Ding, H.; Chen, L.-Q. Random Vibration and Reliability Analysis of Fluid-Conveying Pipe under White Noise Excitations. Appl. Math. Model. 2023, 123, 259–273. [Google Scholar] [CrossRef] [Scilit]
- Sigalotti, L.D.G.; Alvarado-Rodríguez, C.E.; Rendón, O. Fluid Flow in Helically Coiled Pipes. Fluids 2023, 8, 308. [Google Scholar] [CrossRef] [Scilit]
- Raoofian, A.; Peiret, A.; Kövecses, J.; Teichmann, M. Non-Smooth Unilateral Reduced Models for Co-Simulation of Mechanical Systems. Mech. Mach. Theory 2022, 173, 104829. [Google Scholar] [CrossRef] [Scilit]
- Gao, L.; Wang, D.; Wang, S. Research on the Performance of Hydraulic Vibratory Hammer with Coupled Dynamic Model. SN Appl. Sci. 2022, 4, 259. [Google Scholar] [CrossRef] [Scilit]
- Gan, J.; Zhou, Z.; Yu, A.; Ellis, D.; Attwood, R.; Chen, W. Co-Simulation of Multibody Dynamics and Discrete Element Method for Hydraulic Excavators. Powder Technol. 2023, 414, 118001. [Google Scholar] [CrossRef] [Scilit]
- Zhao, L.; Han, L.; Zhang, H.; Jin, X.; Wu, T.; Yang, S. Dynamic Response of a Coal Rock Caving Impact Tail Beam for Hydraulic Support. Sci. Rep. 2022, 12, 11535. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Sun, J.; Han, C.; Liu, D.; Zhao, X.; Gao, C. Simulation and Experimental Validation of Vehicle Dynamic Characteristics for the Hydraulic Rebound Stopper Shock Absorber. J. Mech. Sci. Technol. 2025, 39, 2409–2416. [Google Scholar] [CrossRef] [Scilit]
- Ding, Z.; Sun, S.; Zhu, H.; Yan, Z.; Zhou, Y. Simulation Method for Hydraulic Tensioning Systems in Tracked Vehicles Using Simulink–AMESim–RecurDyn. Actuators 2025, 14, 615. [Google Scholar] [CrossRef] [Scilit]
- Xin, M.; Ren, Z.; Yu, Y.; Tian, Y.; Zhang, H.; Ren, K.; Zhang, Y. Joint Simulation and Experimental Verification of Electromechanical-Hydraulic of Hydraulic Excavator Working Device. Sci. Rep. 2025, 15, 45396. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kumar, A. Pressure-Driven Flows in Helical Pipes: Bounds on Flow Rate and Friction Factor. J. Fluid. Mech. 2020, 904, A5. [Google Scholar] [CrossRef] [Scilit]
- Nguyen, T.T.T.; Vo, T.H.; Cao, D.H.; Pham, N.V.H. A Study on Friction Factor Correlation Considering the Torsion Effect in Helical Pipe Flow. Ann. Nucl. Energy 2025, 217, 111290. [Google Scholar] [CrossRef] [Scilit]
- Prakash, A.; Chandraker, D.K. Numerical & Experimental Study of Single-Phase Flow in Helically Coiled Pipes for Laminar & Turbulent Regimes. Prog. Nucl. Energy 2025, 180, 105637. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.