


Abstract
In this paper, we propose an instantaneous chirp-rate-driven adaptive window Chirplet transform algorithm for the analysis of strong time-varying nonlinear frequency-modulated signals with uncorrelated components. In this approach, the length of the sliding window in the Chirplet transform is dynamically adjusted according to the estimated instantaneous chirp rate of each signal component of an initial time–frequency result from short-time Fourier transform (STFT). A boundary constraint determined from the modal support intervals of the signal is utilized to restrain the allowable searching frequency range of the instantaneous frequency (IF) trajectories and incorporated into a cost-function-based IF extraction method to improve accuracy in the IF estimation. The effectiveness of the proposed algorithm is validated using a simulated nonlinear frequency-modulated (FM) signal with two uncorrelated components, and two sets of experimental bearing vibration signals. It is shown that the proposed algorithm can accurately track the frequency modulation of a strong FM signal dynamically to render an accurate estimation of the IFs and modal amplitudes of a strong FM signal. A comparison study also verifies that the proposed algorithm can produce a better energy-concentrated time–frequency result compared to other commonly employed time–frequency analysis techniques, particularly when the signal is contaminated by noise.
1. Introduction
Condition monitoring (CM) signals from a rotating machine often exhibit non-stationary characteristics due to load variation, speed fluctuation and impulses generated by mechanical defects which pose a challenge in fault diagnosis using conventional time- or frequency-analysis techniques [1,2,3,4]. Time–frequency analysis techniques which can capture the changing dynamic in a signal have thus been developed for the analysis of such signals [5,6,7,8,9]. However, classical time–frequency analysis techniques such as short-time Fourier transform (STFT) [5], wavelet transform [6] or S-transform [7] have inherited limitations in the analysis of non-stationary signals with strong time-varying characteristics. For instance, STFT relies on the assumption that the signal segment enclosed within each sliding window is stationary or quasi-stationary. On the other hand, the scaling rule governing the dilation parameter of the wavelet function to achieve a variable window length in wavelet transform is predefined, meaning that it cannot adaptively adjust itself to match the local time-varying characteristic of a signal. Similarly, the scaling factor employed by S-transform to vary the length of the Gaussian window is fixed and lacks adaptability to the changing dynamic of a windowed signal segment. Furthermore, adjusting the window length or wavelet function alone is insufficient to render a high-resolution time–frequency result in the analysis of strong time-varying frequency-modulated (FM) signals [8].
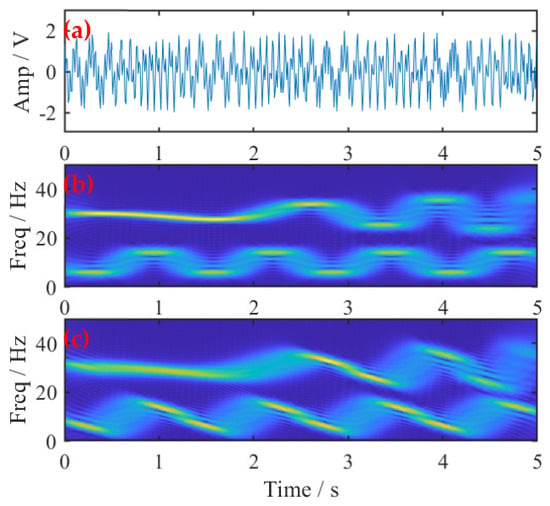
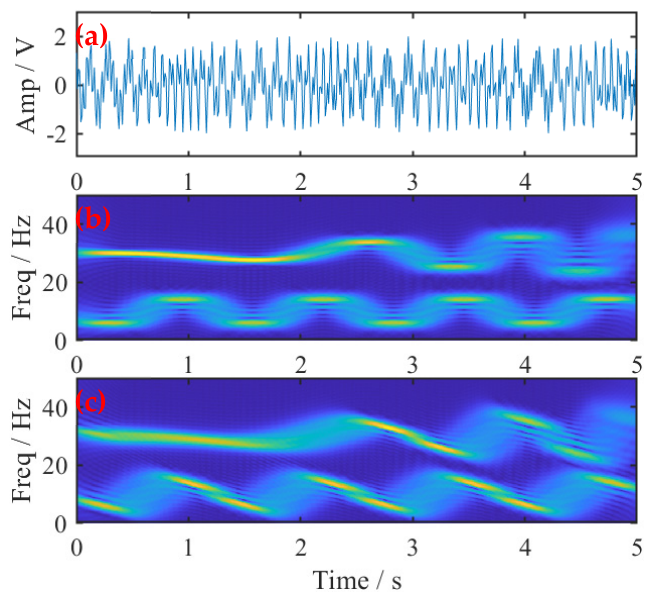
To address this issue, Mann and Haykin [9] proposed a so-called Chirplet transform (CT) by introducing a chirp rate (CR) parameter to match the slope of a linear varying IF of a FM signal. However, the rate of frequency modulation in a FM signal from practical sources under varying speed/load conditions such as those from wind turbines often varies over time. The use of a constant CR in a CT would lead to energy dispersion in the time–frequency result (TFR) [10,11]. Figure 1 provides an example to illustrate the deficits of STFT and linear CT in the analysis of a strong time-varying two-component FM signal.
Figure 1.
A simulated two-component FM signal. (a) The time waveform. (b) STFT. (c) CT with a constant CR.
Aiming to overcome such a deficit, several alternative approaches have been developed in the past to improve the performance of CT in the analysis of strong time-varying FM signals. For instance, Yu and Zhou [12] proposed a generalized linear Chirplet transform (GLCT) algorithm by traversing a predefined set of CRs for each time–frequency point in the spectrogram to form the optimal IF trajectories of the signal in the transform. Since adaptive point-wise parameters were used instead of a constant CR, the approach can render a clear IF trajectory in the analysis of strong time-varying FM signals. However, the approach would also introduce substantial extraneous energies through sidelobes leading to an elevated noise floor in the TFR. Based on a similar idea, He et al. [13] presented an entropy-matching Chirplet transform (EMCT) by partitioning the time–frequency plane of a signal into blocks and traversing a predefined set of CRs to find the minimized Rényi entropy of each block to enhance the energy concentration of the time–frequency result in a CT. The latter approach can largely enhance the computation efficiency of the transform compared to the point-wise traversing approach, though the block-partitioning mechanism could also produce spurious optimized regions in the absence of prior information of a signal leading to artifacts in the TFR.
Meanwhile, Guan et al. [14] proposed a so-called velocity synchronous linear CT by using a time-dependent parameter to replace the constant CR, and selecting the optimal parameter pair comprising the window length and the demodulation parameter based on the calculated maximum kurtosis value in a CT. However, the approach lacks a clear combination rule for the two parameters, which can result in sub-optimal parameter selection. Alternatively, a component-matching chirplet transform was proposed by Li et al. [15] which calculates the optimal demodulation parameters for each analyzing window to match the time-varying CR of the signal. However, the approach is fundamentally constrained by the assumption that the frequency modulation rates for different components in the signal are proportional. Furthermore, the time-varying CR applied in the transform is based on the implicit assumption that the frequency modulation of the signal segment within each sliding window is linear.
To overcome the restriction caused by the linear frequency modulation assumption in a CT, Peng et al. [16] proposed a polynomial CT by employing a polynomial function to depict the frequency variation rate of a time-varying FM signal. Similarly, Yang et al. [17] introduced a spline-kernelled CT by adopting a piecewise approximation of the nonlinear IF in a CT transform to render a better TFR in the analysis of strong non-stationary signals. However, the iterative process adopted by these latter approaches in finding suitable fitting parameters in the transform is very time-consuming. Moreover, the approaches cannot be applied for uncorrelated multi-component FM signals with different frequency modulation rates. Similarly, the scaling-basis chirplet transform proposed by Li et al. [18] and the adaptive sparse matching squeezing chirplet transform proposed by Wu et al. [19] also employ nonlinear kernel functions. Unlike the aforementioned approaches that iteratively fit the IF trajectories and decompose the signal component by component, these two methods exploit the proportional relationships among the derivatives of different orders of the phase to determine a small number of time-varying parameters through various sparsity measures, thereby enabling simultaneous demodulation of multi-component signals. Nevertheless, the effectiveness of such algorithms relies on the prerequisite that harmonic relationships existed between different components in the signal.
Efforts were made by researchers to achieve a good TFR in the analysis of multi-component FM signals through adaptive demodulation window functions. For example, Wu et al. [20] presented an adaptive matching squeezing CT by employing a dual-constraint criterion to find a harmonizable proportional CR adaptively based on the demodulation parameters of different components. Nevertheless, the harmonizable proportional condition is often difficult to satisfy when there are several uncorrelated components in a signal, particularly when the frequency modulations of these components differ significantly from each other. In contrast to the above approach, where adaptive windows were employed directly in a CT, a two-step approach was proposed by Pei et al. [21] in which an initial TFR was produced first by STFT for a rough estimation of the parameters required in the adaptive demodulation window functions of a CT. Similarly, an initial TFR was used by Czarnecki et al. [22] to compute the instantaneous chirp rate of each component in a signal to construct a time–frequency-varying demodulation window function in a CT for high-resolution TFR. However, the window parameters in these approaches were determined solely based on the frequency modulation rate of the center point in each sliding window, though the frequency modulation rate of other points in the window may differ substantially from that of the center point. This then motivated the work presented in this paper, where a chirp-rate-driven adaptive window CT (CDACT) is proposed by jointly adjusting the window length and the demodulation parameter to suit the local characteristic of a multi-component nonlinear FM signal in the CT.
The remainder of this paper is organized as follows: Section 2 introduces the theoretical background of Chirplet transform and a discussion on factors affecting the frequency resolution of a CT. Section 3 elaborates the theoretical principle of the proposed algorithm and its implementation details. Section 4 presents the validation of the proposed algorithm using a simulated time-varying two-component FM signal and two experimental bearing defect signals. Conclusions from this study are drawn in Section 5.
2. Materials and Methods
2.1. Theoretical Background
2.1.1. Theoretical Basis of Chirplet Transform
For a given real value signal , where and denote the instantaneous amplitude and phase of the signal component in the signal, respectively, CT can be expressed as follows [12]:
where is a real symmetric Gaussian window function. The term signifies a frequency demodulation operator where is the imaginary number and represents the chirp rate, which is a constant in a linear CT.
Equation (1) becomes a STFT when . Thus, the fundamental difference between CT and STFT lies in their underlying signal models, i.e., STFT assumes that the signal segment within a sliding window is stationary or quasi-stationary, whereas a linear CT assumes that the signal segment within a window exhibits a linear frequency modulation with a constant CR. The differences between the two can be further exemplified by the Taylor expansion of a signal phase, as follows:
where is the derivative of the phase.
Meanwhile, if there is a sufficiently small such that and for , the signal can be simplified as follows [23]:
Equation (1) then becomes
where is the window length parameter in the transform.
The modulus of the CT can be obtained from Equation (4) as follows [20]:
It can be readily observed that for a given frequency, the amplitude of a time–frequency point in the TFR from a CT is related to the degree of demodulation.
2.1.2. Frequency Resolution
The frequency resolution of a CT can be derived from the second-order moment of the window function spectrum [8] given by
From Equation (6), the frequency resolution of the transform can be obtained:
where is the first-order moment of the window function spectrum , and is the energy spectral density of , which is given by
Substituting Equation (6) into Equation (8) yields
Substituting Equations (6) and (9) into Equation (7) produces
Equation (10) indicates that the frequency resolution in the transform is inversely proportional to the window length parameter ; a larger would render a better frequency resolution and vice versa.
2.2. The Proposed Algorithm
2.2.1. The Motivation
Considering that the modulus of the time–frequency result from a CT, as expressed by Equation (5), is closely related to the level of frequency demodulation, it would be useful to disclose how the frequency demodulation affects the frequency resolution of the TFR. To this end, an error function is defined to represent the difference between the frequency modulation and the demodulation at each time–frequency point in a CT as , where is the constant chirp rate in a CT demodulation. The Fourier transform of the error function can then be expressed as
where .
Substituting Equation (11) into Equation (8) yields
Substituting Equations (11) and (12) into Equation (7) produces
It is evident from Equation (13) that when , the frequency resolution of the signal depends solely on the window length parameter . Conversely, when , the presence of the term can lead to a degradation of the frequency resolution in the transform, thereby leading to energy dispersion in the TFR.
Now, we further consider that the chirp rate is a time-varying parameter such as that considered in ASDT [8], and the error function can then be revised to
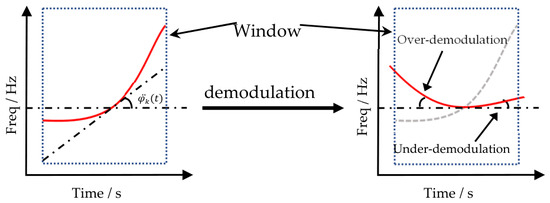
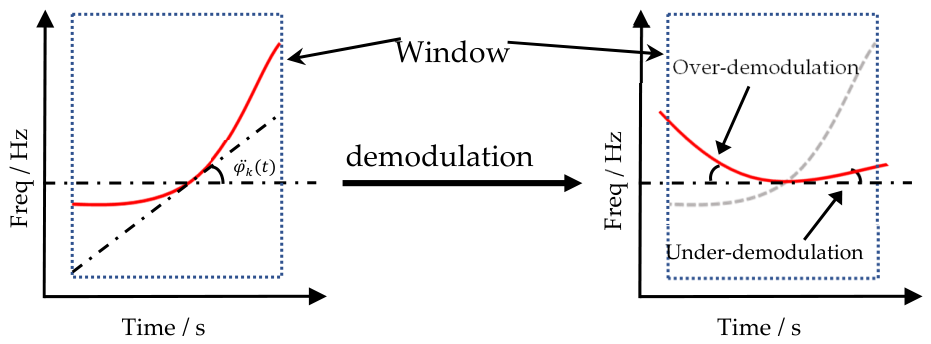
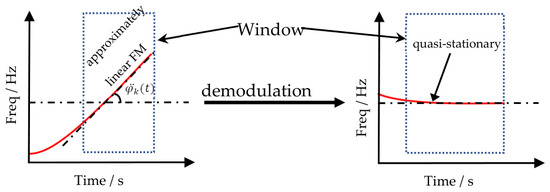
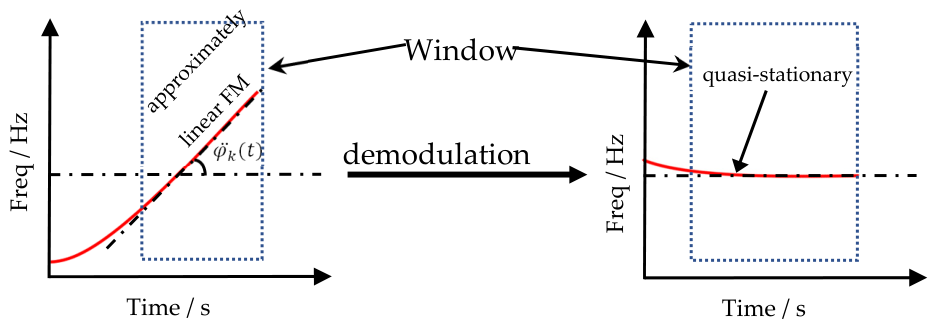
Equation (14) can be made as close to zero for each windowed signal segment if the variation in can closely reflect the true frequency modulation of the signal segment in the window. A major drawback of the approach in Ref. [8] is that it uses a constant window length in the transform and implicitly assumes that the frequency variation in each windowed signal segment is a linear modulation, which can lead to under- or over-demodulation of the signal segment as depicted in Figure 2. The situation can become worse in the analysis of nonlinear FM signals or signals containing multiple uncorrelated time-varying components. For such cases, discrepancies in the demodulation (i.e., a non-zero ) can result in a large divergence in the TFR.
Figure 2.
A schematic illustration of the drawback of CT algorithms in demodulating strong time-varying signals.
2.2.2. The Approach
It is thus necessary to find an adjustable window function and chirp rate parameter that can adapt themselves to the local frequency modulation characteristics of each time–frequency region in a CT. To this end, this paper proposes a chirp-rate-driven adaptive window CT algorithm by adaptively adjusting the length of the sliding window based on the local frequency modulation characteristic to ensure the error between the chirp rate and the actual frequency modulation rate of component , within a sliding window that is smaller than a preset threshold. Accordingly, the CT algorithm given by Equation (1) is revised to
where represents the adaptive window function determined independently by the local chirp rate variation in each uncorrelated component in the signal. is the represented chirp rate of the window function determined at the center point of the windowed signal segment of the component. The approach can then ensure that the frequency modulation of each windowed signal segment for each component is close to a linear modulation to reduce the error induced by over- or under-demodulation in the CT (see the graphical illustration in Figure 3).
Figure 3.
An adaptive window approach.
To demonstrate that the proposed algorithm can render an accurate TFR in the analysis of a strong time-varying FM signal, Equation (15) is simplified at the instantaneous frequency trajectory of a signal component, i.e., at :
where signifies a frequency-dependent Gaussian window:
Using a proper parameter design such that the demodulation term in Equation (16) satisfies
Equation (16) can be further simplified to
If an amplitude-normalized window function is adopted such that
the transform can then be approximated by
From Equation (21), the modulus of the transform is then
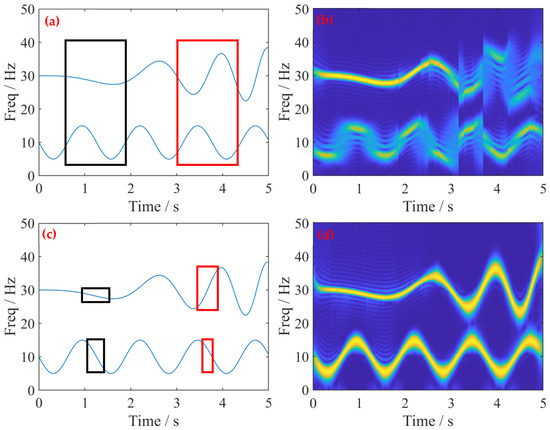
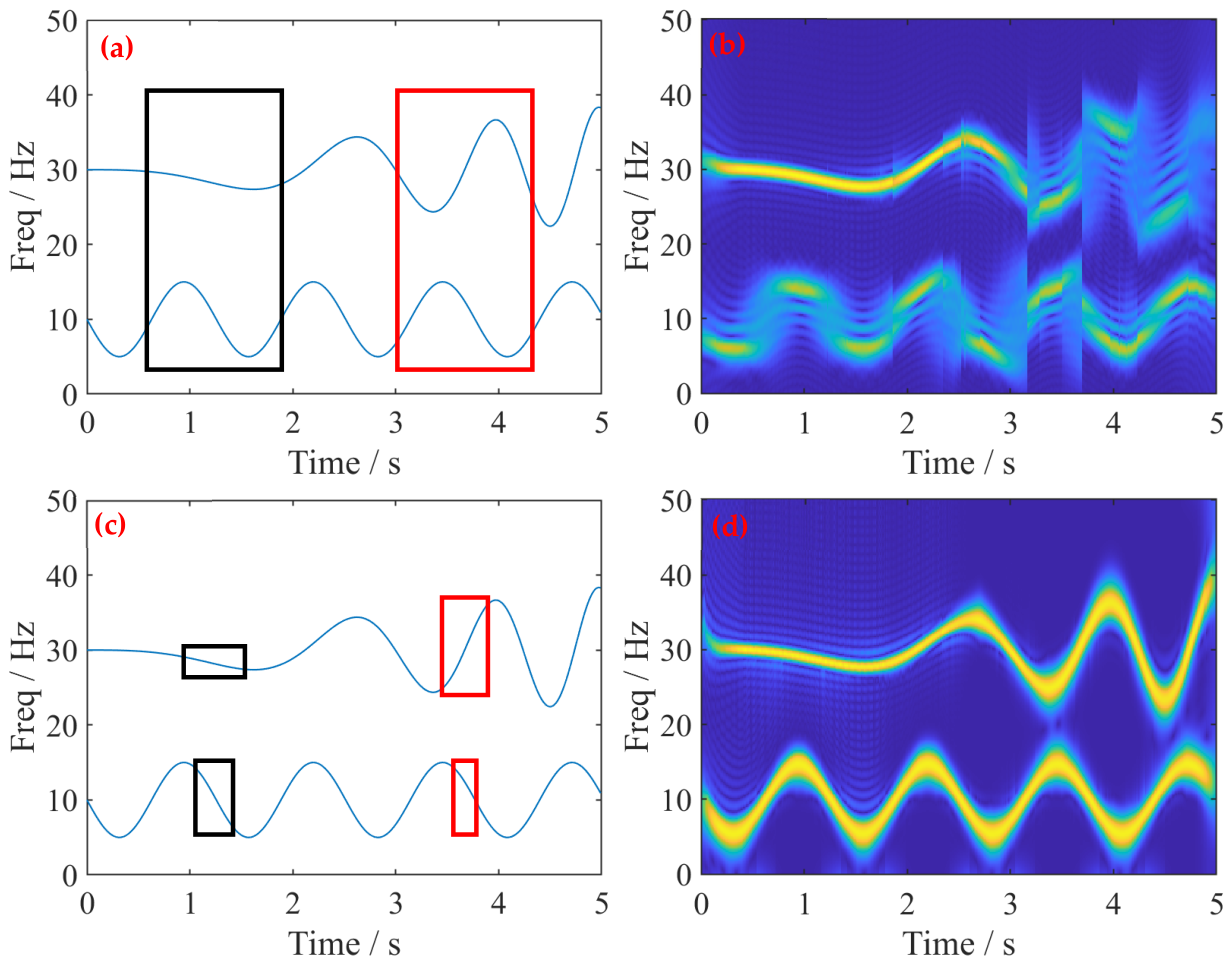
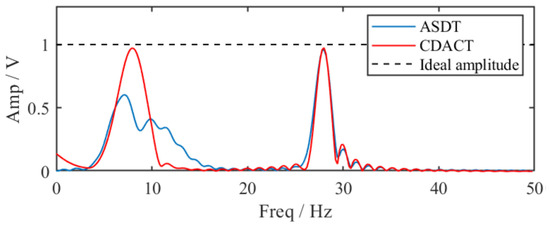
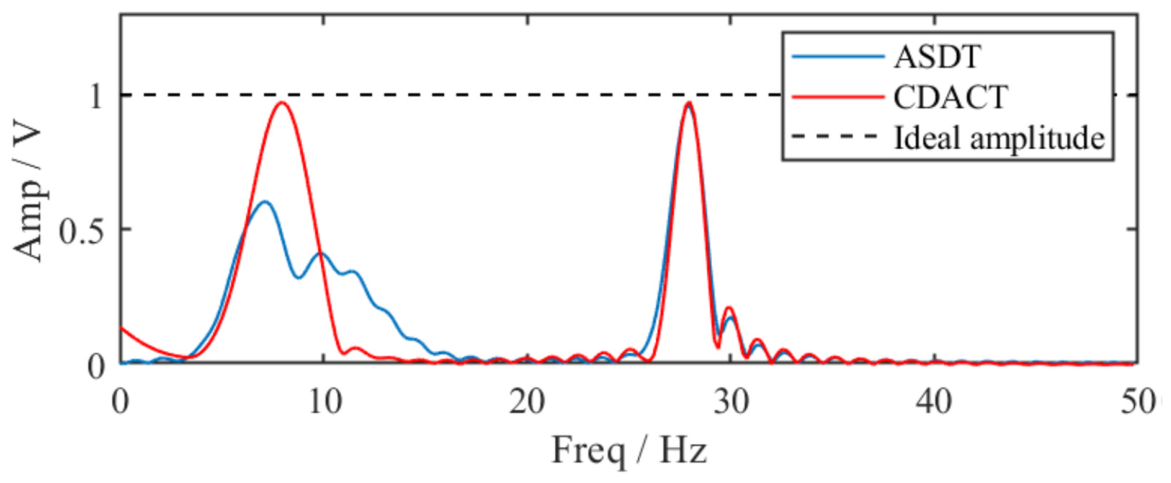
Equation (22) indicates that with a proper designated set of parameters based on the extracted actual chirp rate of a signal, the signal amplitude can be well preserved at the instantaneous frequency of the signal components using the proposed algorithm. The simulated signal presented in Figure 1 is used here again to exemplify the effect of the transform using Equation (15), and the result is shown in Figure 4 together with that obtained using ASDT for comparison. It is shown that the proposed CDACT algorithm can yield a much better TFR than ASDT in the analysis of strong time-varying multi-component FM signals. Figure 5 compares the frequency spectrum amplitude at a slice at of Figure 4b,d. The result confirms that a highly accurate TFR with signal amplitudes close to the original can be produced using the proposed algorithm.
Figure 4.
(a) The ideal IFs of the simulated two-component signal in Figure 1 and a fixed-length sliding window, (b) the ASDT result, (c) the ideal IFs and adaptive windows, and (d) the CDACT result.
Figure 5.
A slice at from the time–frequency result shown in Figure 4.
2.2.3. Adaptive Window Length Determination
Inspired by the approach of adaptive short-time Fourier transform (ASTFT) [24], the adaptive window length in the proposed algorithm is determined based on the principle in which the frequency modulation rate of each signal segment within a sliding window is either a constant or near a constant. In other words, the frequency modulation rate for each windowed segment can be partitioned based on the third derivative of the instantaneous phase as
Therefore, the theoretical permissible maximum window length at any given time should satisfy the following equation:
where is a small threshold value to ensure that all time–frequency points enclosed in each sliding window have the same or similar frequency modulation rates. The window length of a Gaussian window can be defined by its full width at half maximum of the windowed amplitude, such that [25]
where signifies a time-dependent window length parameter.
Equation (25) can also be expressed as
The window length parameter determined by Equation (26) can be employed to obtain the window length adaptively on a single-component signal with a time-varying frequency modulation rate, and the frequency modulation rate at the center point of a respective window can be used to demodulate the signal segment of the window in the transform.
2.2.4. Instantaneous Frequency Extraction
Accurate extraction of IF trajectories from the initial TFR is critical to the performance of the proposed algorithm. Conventional IF extraction methods typically identify the ridge points by searching for peaks in the TFR along the time axis, with a regularization term that balances trajectory smoothness against sensitivity to local frequency variations [26,27]. However, when signal components are closely spaced in the time–frequency plane or the signal-to-noise ratio (SNR) is low, the estimation error of such methods tends to increase substantially. This is because spurious peaks arising from noise or spectral leakage may be erroneously selected as the ridge points, causing the IF trajectory to “jump” between adjacent modes. In recent years, boundary constraint strategies have been introduced to improve the accuracy of IF extraction [28,29]. The core idea is to restrict the search range of ridge candidates within prescribed time–frequency boundaries, thereby preventing the ridge extraction algorithm from being attracted to spurious peaks outside the true modal support regions.
To this end, this study proposes an adaptive boundary constraint method based on the statistical characteristics of time–frequency magnitudes. The method estimates the noise floor directly from the initial TFR and dynamically determines the effective modal support intervals at each time instant according to the noise level, enabling the search boundaries to adapt to the time–frequency distribution of the signal. Consequently, the robustness of the IF estimation is significantly improved. The specific steps are as follows:
- Obtain the initial time–frequency result, ;
- For each time instant , the average magnitude of the TFR over the entire frequency range of interest is computed as an estimate of the background noise level :This global average provides a simple but effective reference for distinguishing meaningful signal energy from background fluctuations, provided that the signal components occupy only a limited portion of the frequency axis.
- A time-dependent threshold is then defined by scaling the estimated noise floor with a user-specified coefficient :The parameter controls the sensitivity of the threshold. A larger suppresses more low-energy content, thereby reducing the risk of spurious ridge detection, but may also remove weak signal modes. In practice, is selected based on the expected SNR and the dynamic range of the signal components.
- At each time instant , the set of frequency intervals within which at least one time–frequency point has a magnitude exceeding the threshold is identified. These intervals, denoted asare defined such that each interval satisfieswhile the boundary points fall below the thresholdMoreover, the intervals are mutually disjointed:These intervals represent the estimated time–frequency supports of the individual signal modes at time . By restricting subsequent ridge extraction to these intervals, the influence of noise-dominated regions and interfering modes is substantially reduced. This is particularly beneficial when modes are closely spaced, because the thresholding step removes the low-energy “bridges” between adjacent modes that often cause conventional ridge extraction algorithms to jump across components.
- The TFR values outside the identified modal support intervals are set to zero, yielding a masked representation . The IF trajectory of the mode is then extracted by maximizing the following cost function [30,31]:The first term accumulates the TFR energy along the candidate ridge, thereby favoring trajectories that pass through high-energy regions. The second term penalizes rapid variations in the IF: the term weighted by penalizes the first derivative (i.e., large instantaneous chirp rates), while the term weighted by penalizes the second derivative (i.e., abrupt changes in chirp rate). Together, these regularization terms encourage smooth IF trajectories. Finally, the IF of the signal component is obtained as
2.2.5. Implementation Details
Detailed implementation steps of the proposed algorithm are as follows:
- Obtain the initial TFR of a signal using STFT, and estimate the number of components K in the signal;
- Extract the IF trajectory of each component using Equations (27)–(34), and then the corresponding and by differentiation;
- Determine the window length parameter for each component at different time instants using Equations (24) and (26);
- Calculate the chirp rate at the center point of each sliding window for each component and use it as the representative chirp rate of the window in the transform;
- Employ the proposed CDACT using Equation (15), where and are used for each component in the transform, and the parameters and for frequencies away from the IF trajectories of the components are determined by a linear interpolation between neighboring components to render an output TFR.
Furthermore, considering that the IFs extracted from the initial TFR of a signal could have estimation errors, the and determined by Steps (3) and (4) could also contain some bias. A two-step approach is then implemented to eliminate the bias in practical applications, as follows.
(1) Since the two parameters and for each signal component are determined based on the initial estimated IF of the component, which could contain some bias in the estimation, the two parameters are applied on a designated frequency bandwidth centered around the extracted IF trajectory in the transform to reduce the estimation error [32] such that
where is the unilateral bandwidth of the demodulation window, which can be set according to the extracted , but should satisfy
(2) A moving average process is applied to the window length parameter in the execution of the proposed algorithm to prevent a drastic jump of the window length between two sequential windows, as follows:
where is the truncated window length.
The proposed algorithm consists of three main steps. First, the initial time–frequency analysis is performed. When STFT is adopted, the computational complexity of this step is , where denotes the number of time frames. Second, the IF trajectory extraction is carried out. The proposed boundary detection algorithm compares each time–frequency point with a preset threshold, with a complexity of , where denotes the number of positive frequency points. Assuming that the search range of the IF trajectory at time is points, the search complexity for IF trajectories is . Third, the adaptive demodulation is performed by designing a demodulation window point by point, with a complexity of , followed by fast Fourier transform with a complexity of .
2.2.6. Signal Reconstruction and Mode Decomposition
As the proposed CDACT is performed by a joint adaptive matching of the window length and the demodulation parameter , it can produce a high-resolution TFR in the analysis of strong time-varying multi-component FM signals. Furthermore, the proposed algorithm can also retain the signal reconstruction and mode decomposition capacity as elaborated below.
According to Equation (21), the FM signal can be reconstructed using
and the mode decomposition can be achieved with
3. Results
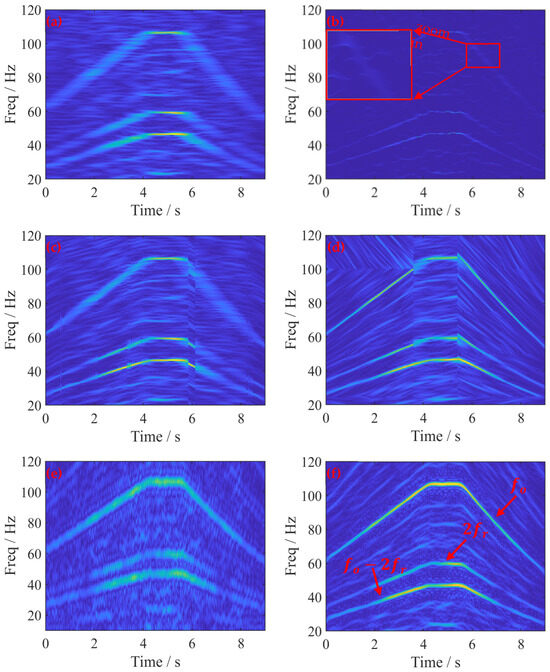
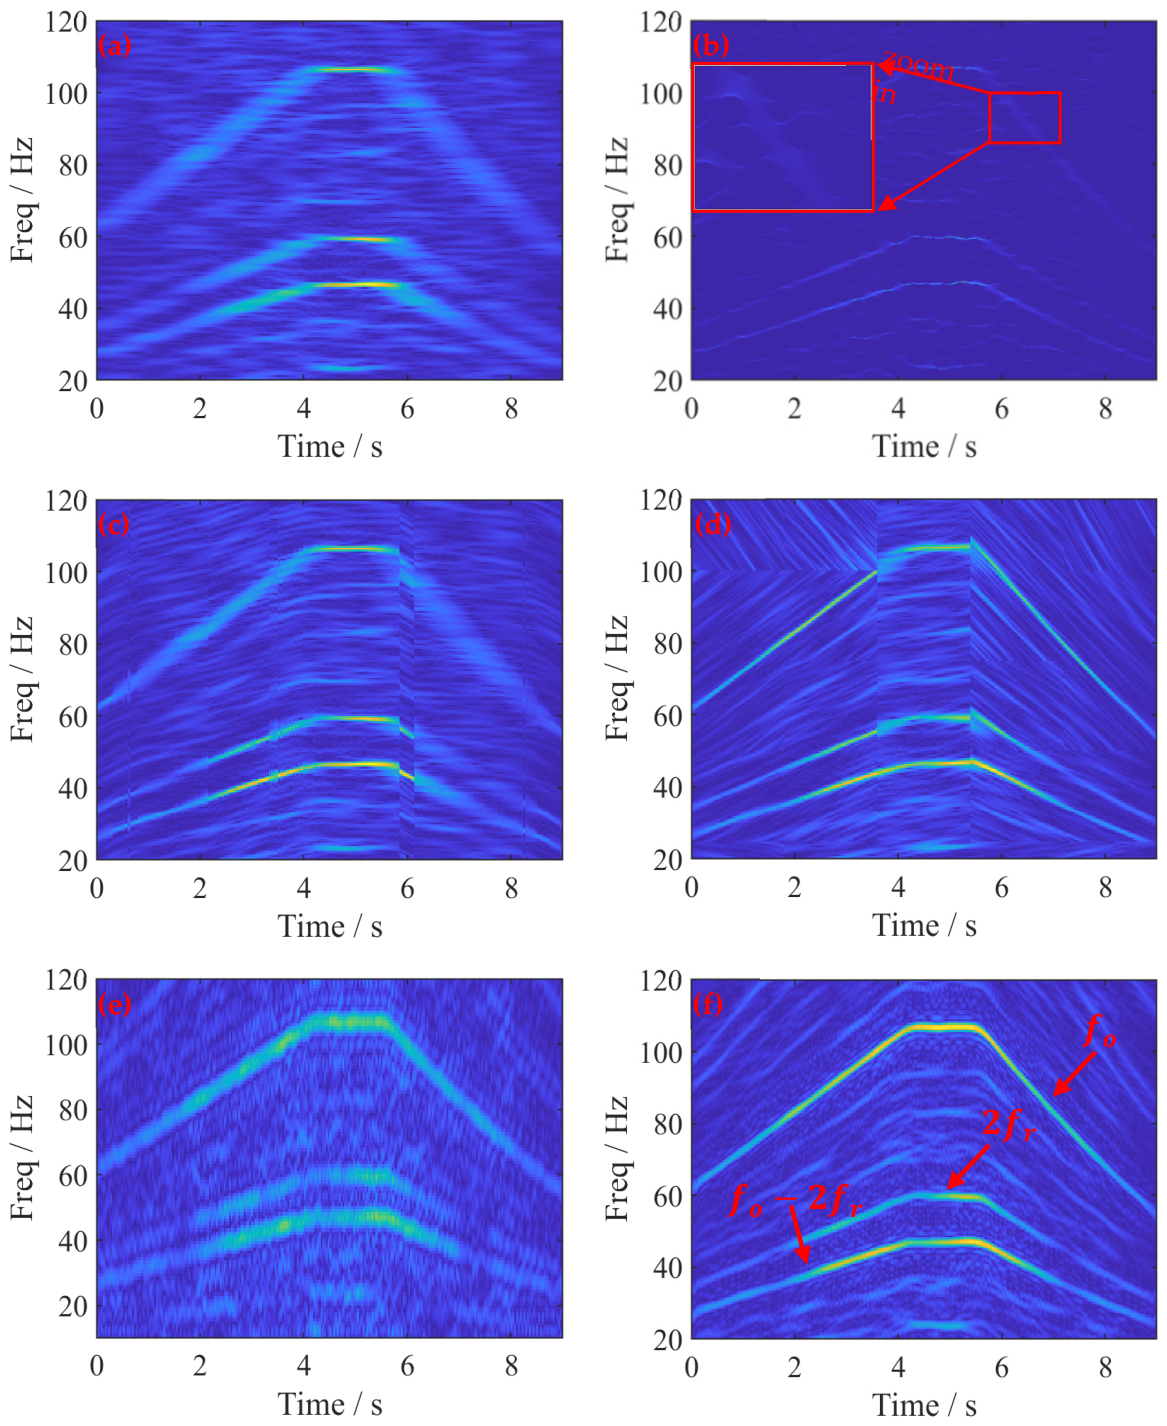
In this section, the proposed algorithm is compared with five representative time–frequency analysis techniques, namely STFT, synchrosqueezing transform (SST), ASDT, EMCT, and PCT, using two simulated signals and two experimental signals. These methods cover different categories of time–frequency analysis: STFT as a classical linear time–frequency technique, SST as a time–frequency post-processing technique, ASDT and EMCT as parameterized linear time–frequency techniques, and PCT as a nonlinear time–frequency technique. The comparison is conducted from two aspects, time–frequency energy concentration and the readability of the TFR, so as to validate the effectiveness of the proposed algorithm. For EMCT, the time–frequency plane is divided into a 5 × 5 grid of blocks in all the following cases. For PCT, five iterations are used to strike a balance between analysis accuracy and computational complexity.
3.1. A Simulated Two-Component Time-Varying Fm Signal
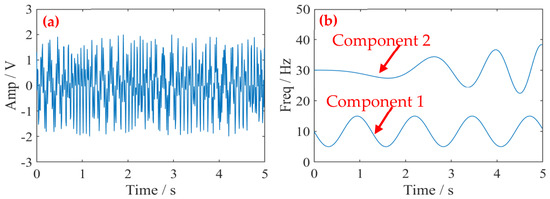
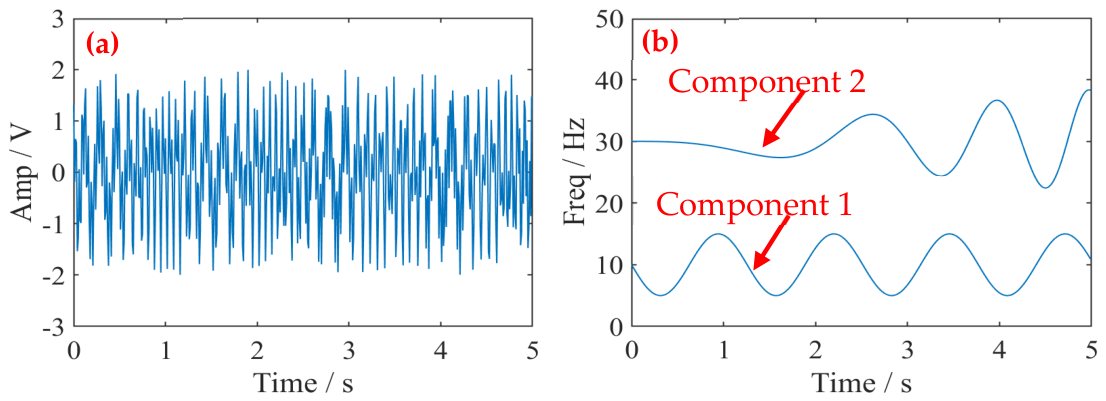
A two-component time-varying FM signal is simulated using
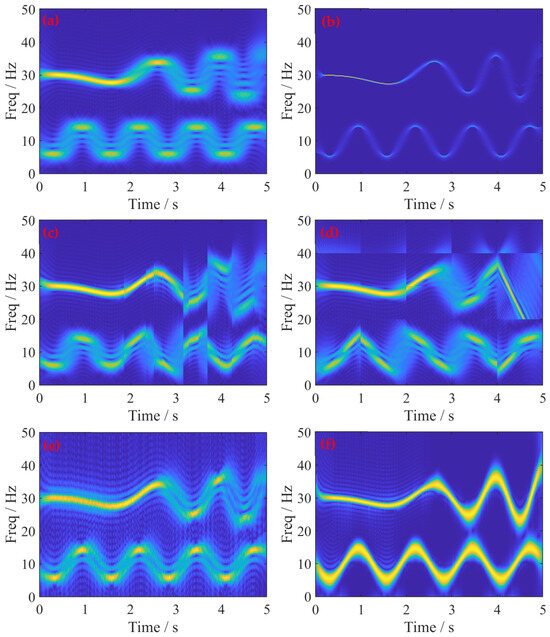
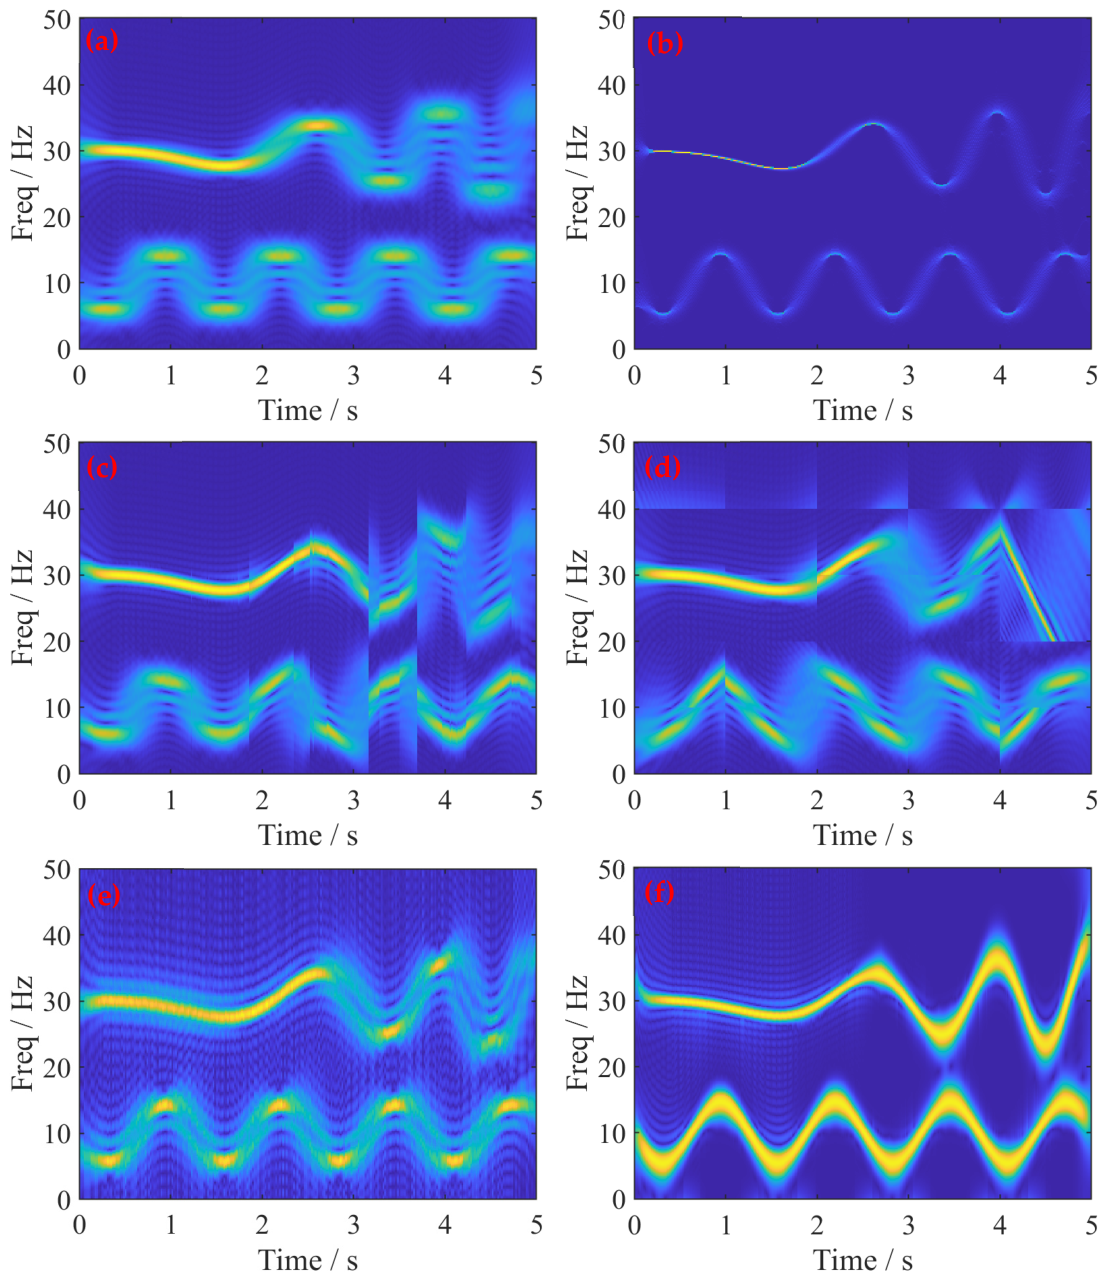
The sampling frequency used in the simulation is 100 Hz with a time duration of 5 s, and the error threshold is set to 0.05 to strike a balance between the mean error and Rényi entropy of the transform, which will be discussed below. The time waveform, ideal IF trajectories and the TFR of the simulated signal using different algorithms are compared in Figure 6 and Figure 7, respectively.
Figure 6.
The simulated two-component FM signal. (a) The time waveform. (b) IF trajectories.
Figure 7.
The time–frequency results: (a) STFT, (b) SST, (c) ASDT, (d) EMCT, (e) PCT, (f) CDACT.
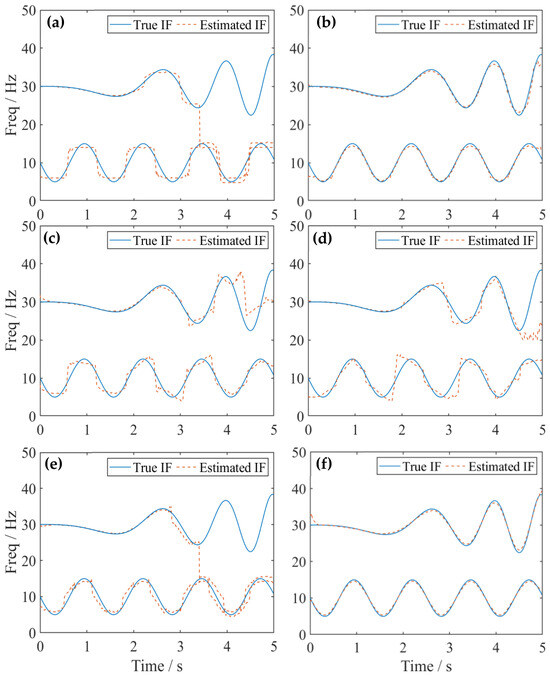
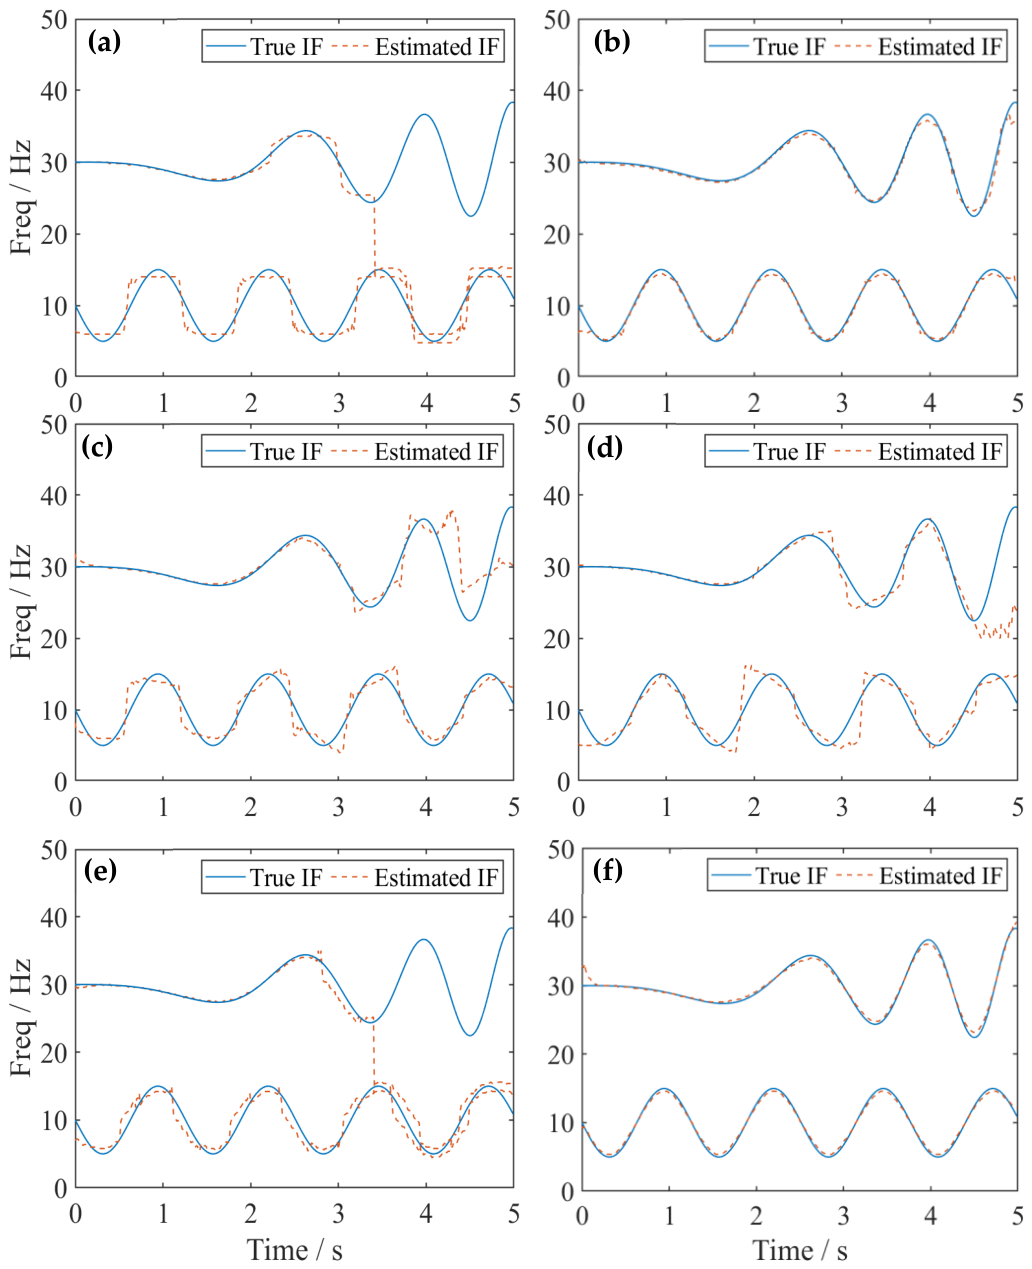
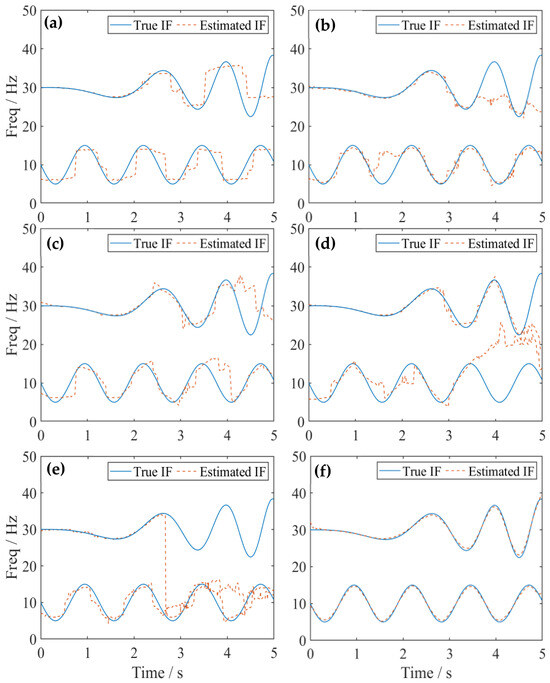
It is shown that both STFT and SST will yield a diverged TFR when the frequency modulation of the signal is strong, whereas ASDT fails to render an energy-concentrated TFR as the two signal components have different frequency modulation rates, so the optimal parameters calculated by ASDT would not match well with the true CRs of the two components synchronously. On the other hand, EMCT fails to produce a meaningful TFR of the signal due to mismatch between the block partition and the time-varying FM characteristics of the signal at different time instants. When the partition blocks are too few, a single block may contain multiple signal components, causing difficulties in calculating the minimum Rényi entropy of the block. When the partition blocks are too many, the approach can introduce spurious signal energies, causing a disruption to the TFRs between different blocks. Likewise, when the number of iterations is insufficient, the demodulation parameters fitted by PCT may not be sufficiently accurate, resulting in substantial energy dispersion in the time–frequency result. In contrast, as shown in Figure 7f, CDACT can effectively capture the changing dynamic of all signal components to render an energy-concentrated TFR for the strong time-varying two-component FM signal. Furthermore, Figure 8 compares the IF trajectories of the two components extracted from the TFRs using the above-mentioned algorithms, and the algorithm closely matches the true IFs of the two signal components. The result confirms that the IFs extracted using the proposed algorithm closely match the true results of the two signal components.
Figure 8.
A comparison between the extracted and the true IFs of the signal: (a) STFT, (b) SST, (c) ASDT, (d) EMCT, (e) PCT, (f) CDACT.
The mean error (ME) between the true IFs () and the extracted IFs () is one of the key indicators for measuring the effectiveness of a time–frequency transform in additional to the Rényi entropy, which is calculated using
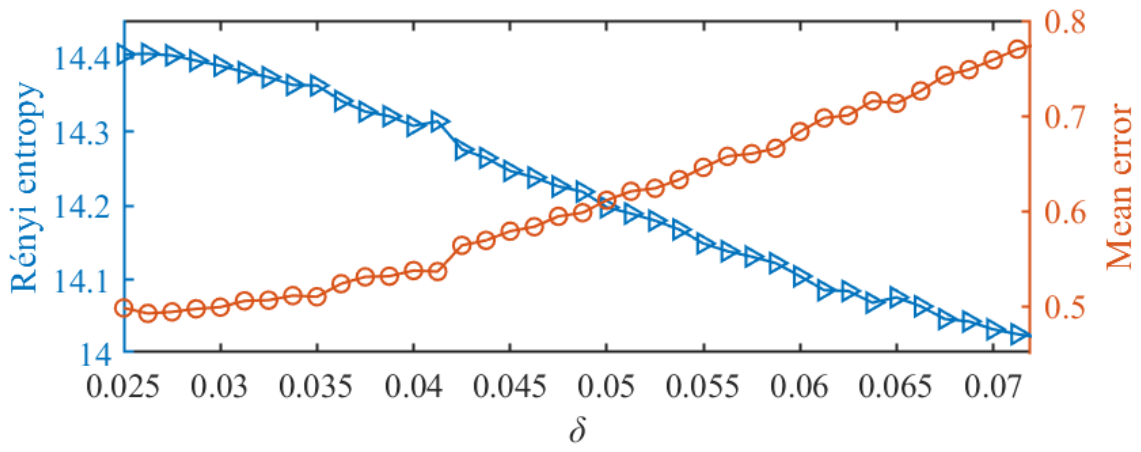
Figure 9 compares the variations in the mean error and the Rényi entropy of the TFR using the proposed algorithm for different preset threshold values . It is shown that when , it will strike a balance between the energy concentration of the TFR (a small Rényi entropy) and an accurate extraction of the IFs (a small ME) of the transform, which is adopted throughout this study.
Figure 9.
Variations in Rényi entropy and the mean error for different threshold values .
Table 1 compares the Rényi entropies of the TFRs using the algorithms cited above. It is shown that the Rényi Entropy of the proposed CDACT algorithm is the smallest compared to the other algorithms, except SST. It is noted that the small Rényi entropy using SST reassigns the time–frequency coefficients into the estimated IF trajectories of the signal in post-processing which can sharpen the energy concentration of the TFR. However, the reassignment of the coefficients can also lead to inaccurate TFR in the presence of bias in the estimated IFs, particularly under the influence of strong noise interference (to be illustrated further in the following subsection on the analysis of the noise-added signal). Table 2 compares the mean errors of the extracted IFs using various algorithms. It shows that the proposed CDACT renders the smallest mean error compared to all other algorithms.
Table 1.
A comparison of the Rényi entropies calculated using various algorithms.
Table 2.
A comparison of the mean errors calculated using various algorithms.
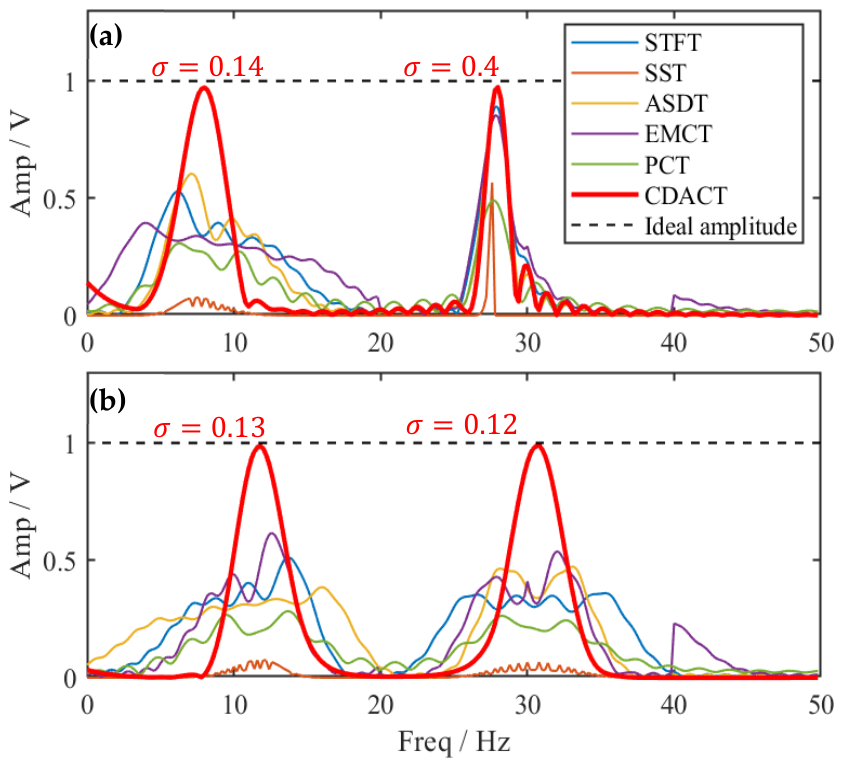
To illustrate the signal reconstruction capacity of the proposed algorithm, Figure 10 compares the slices of the TFRs in Figure 7 at time instants of 1.8 s and 3.7 s, respectively, where the adaptive window length used by CDACT at the two instants is annotated in the figure whilst a fixed window length of is used for all other algorithms. It is shown that the peak amplitudes of the two components from the CDACT result closely match the true amplitudes of the two components, indicating that the energy leakage of the TFR using the proposed transform is the smallest.
Figure 10.
The slices of time–frequency results of the signal at (a) and (b) .
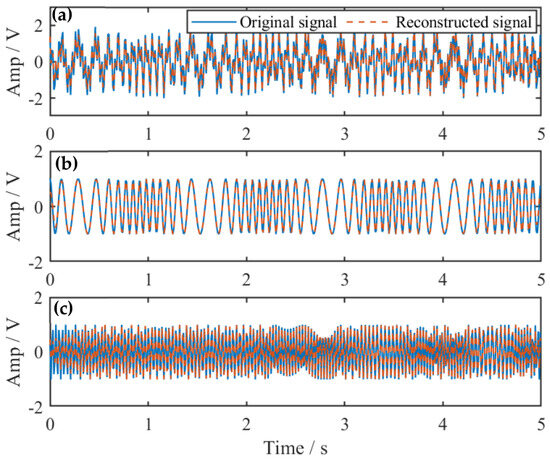
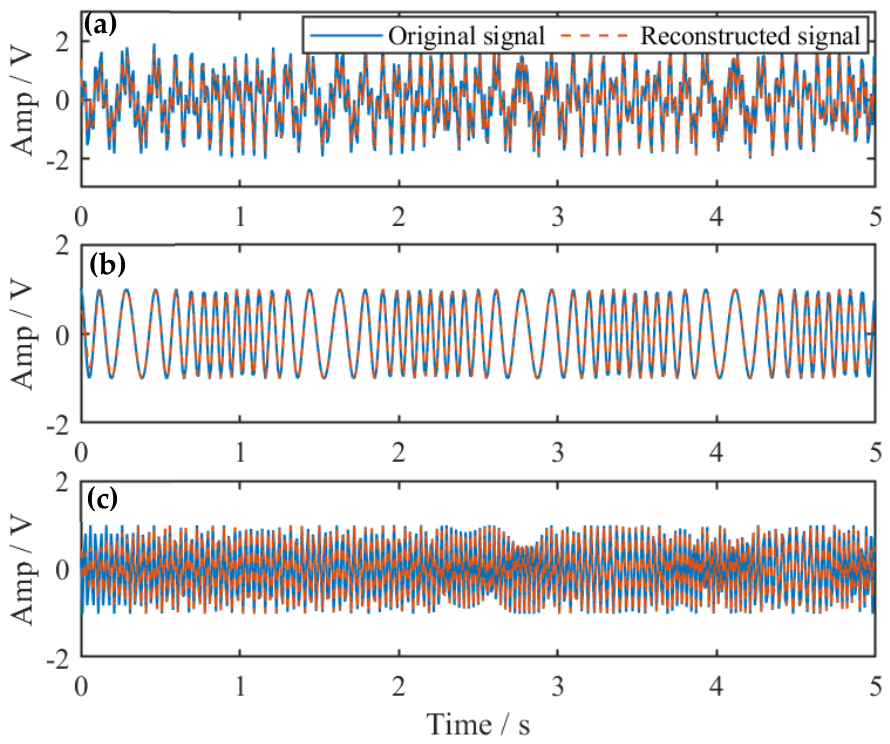
To further exemplify the effectiveness of the proposed algorithm in the analysis of strong non-linear FM signals with uncorrelated signal components, Figure 11 compares the time waveforms of the original and the reconstructed signals as well as the respective signal components using the proposed algorithm. The result confirms that the proposed algorithm has excellent signal reconstruction and mode decomposition capacities in the analysis of strong time-varying FM signals.
Figure 11.
A comparison of the time waveforms: (a) The origin and the reconstructed signals. (b) Component 1. (c) Component 2.
3.2. The Noise-Added Signal
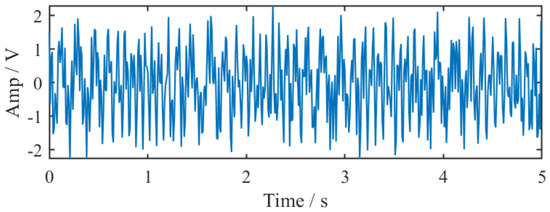
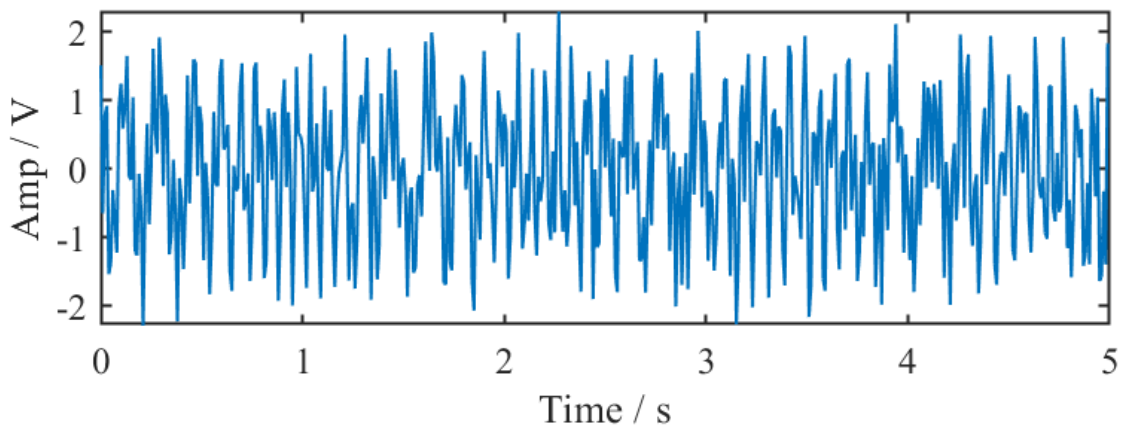
To examine the robustness of the proposed algorithm under noise interference, broadband Gaussian white noise with a signal-to-noise ratio of 5 dB is added to the simulated signal, and the time waveform of the noise-added signal is shown in Figure 12. Figure 13 compares the extracted IF trajectories of the noise-added signal with the true IFs using STFT, SST, ASDT, EMCT, PCT and the proposed CDACT algorithm. It can be seen that the proposed algorithm can render the most closely matching IFs for the noise-added signal, whereas large deviations can be observed between the true and the extracted IFs of the signal using all other algorithms.
Figure 12.
The time waveform of the noise-added signal.
Figure 13.
The estimated IF trajectories of (a) STFT, (b) SST, (c) ASDT, (d) EMCT, (e) PCT, and (f) CDACT.
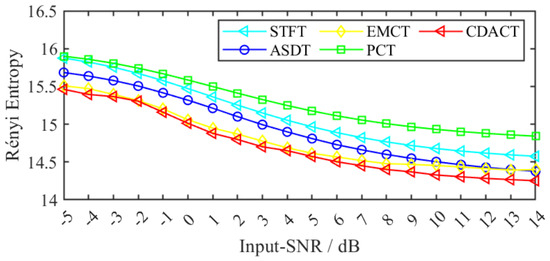
Furthermore, since the bias introduced in the initial IF estimation can propagate to the subsequent adaptive window design and demodulation steps, it is necessary to evaluate the effectiveness of the proposed algorithm when the signal is contaminated by noise of different SNRs. Figure 14 compares the Rényi entropies of the TF results obtained using the selected algorithms of the noise-contaminated signal with different SNRs. It is shown that the proposed algorithm renders a comparatively smaller Rényi entropy value to other time–frequency analysis algorithms regardless of the level of noise contamination. SST is excluded from this comparison as it performs post-processing by squeezing the signal energy to the IF trajectories, and thus will have a much smaller Rényi entropy.
Figure 14.
A comparison of the calculated Rényi entropies for various time–frequency analysis techniques.
3.3. An Experimental Bearing Defect Signal
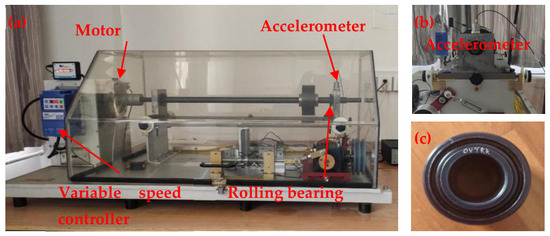
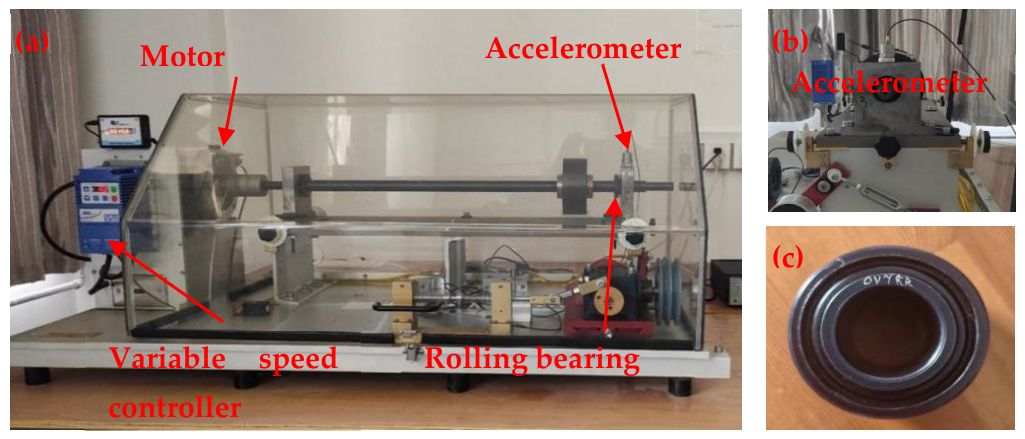
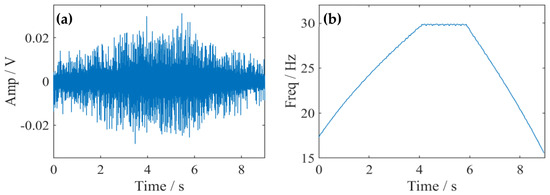
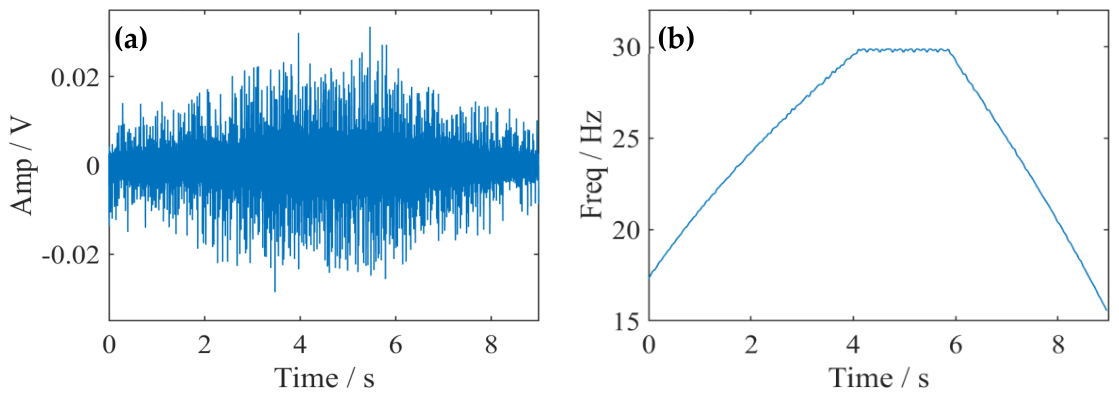
The experimental bearing defect signal used in this subsection was acquired from an in-house Spectra-Quest bearing fault simulator at Qingdao University of Technology. The test bearing used in the experiment was a Type Er-16k rolling element bearing (Sealmaster, Regal Rexnord, Milwaukee, WI, USA) which has a built-in outer race fault. According to the bearing specification, the characteristic frequency of the outer race fault is 3.572, where signifies the shaft-rotating frequency. A B&K-type 4370 accelerometer (Hottinger Brüel & Kjær A/S, Nærum, Denmark) was placed on the top of the test bearing house as shown in Figure 15 to monitor the bearing vibration during the test. The sampling frequency used in the data acquisition was 10 kHz, and the time recording length for each data point was 9 s. Figure 16 shows the time waveform of the condition monitoring data and the corresponding shaft speed profile during the test. In this test, the shaft speed increased from around 1750 rpm to 3000 rpm in about 4 s and then stayed steady for about 2 s before decreasing to around 1550 rpm within 3 s.
Figure 15.
(a) The Spectra Quest bearing fault simulator. (b) The side view of the simulator. (c) The test bearing.
Figure 16.
(a) The time waveform of the bearing test data. (b) The profile of the shaft rotating speed.
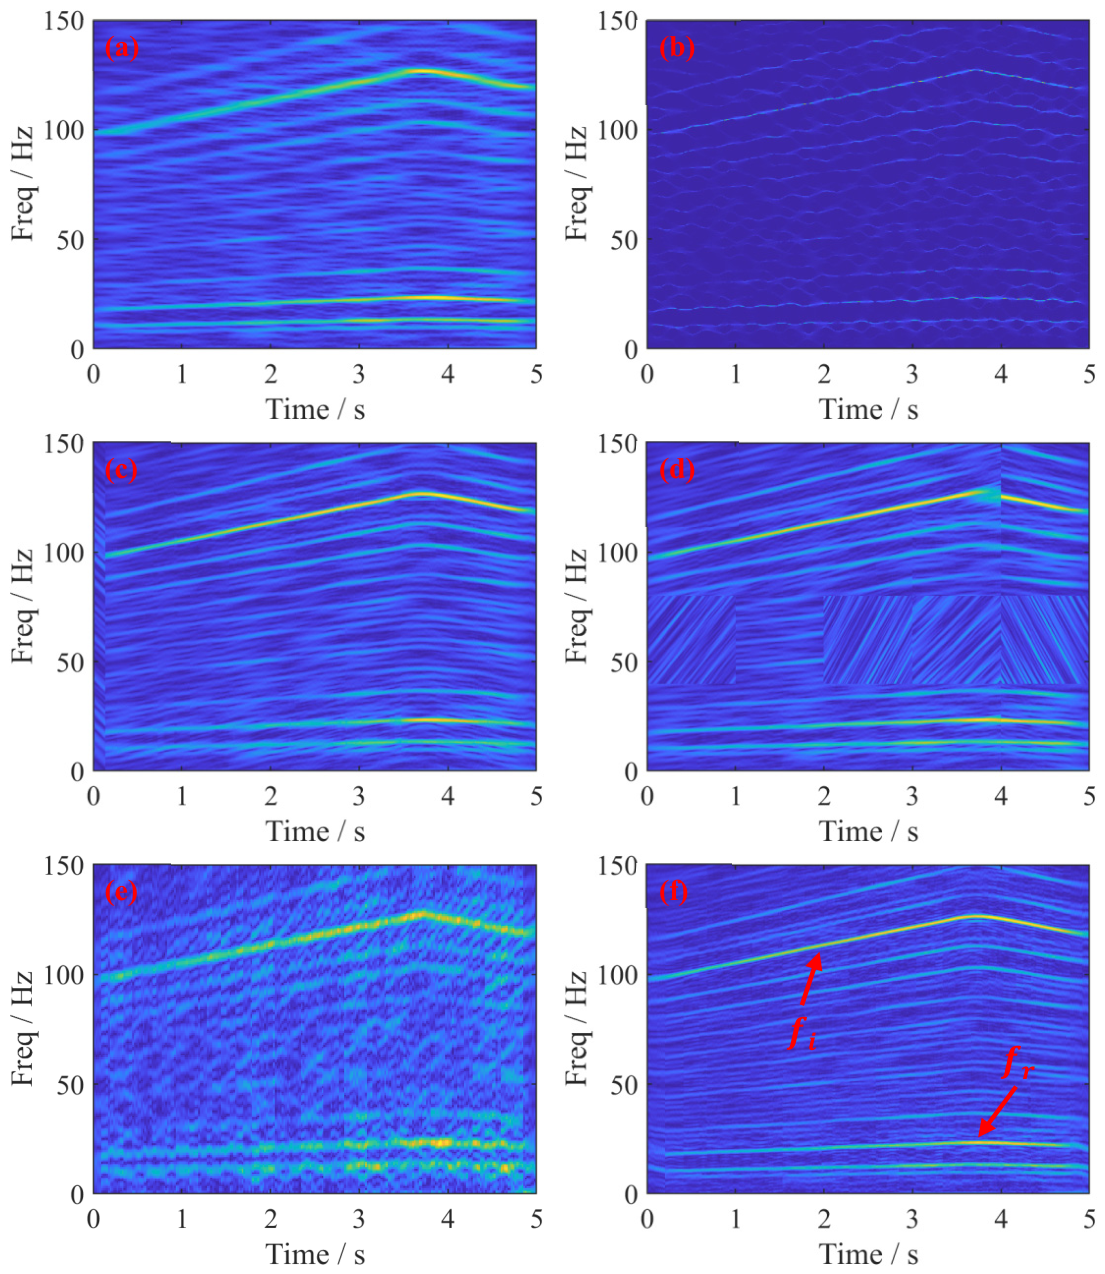
The TFR of the bearing defect signal analyzed using the proposed algorithm is shown in Figure 17, together with the signals from STFT, SST, ASDT, EMCT, and PCT for comparison. It is shown that the proposed CDACT yields the most accentuated TFR compared to the others. Note: the zoom-in window in Figure 17b highlights the energy divergence of the TFR using SST.
Figure 17.
The time–frequency results: (a) STFT, (b) SST, (c) ASDT, (d) EMCT, (e) PCT, and (f) CDACT.
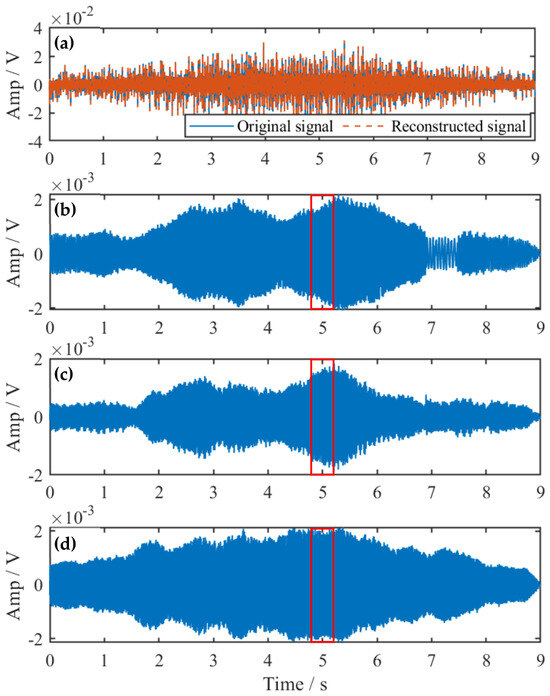
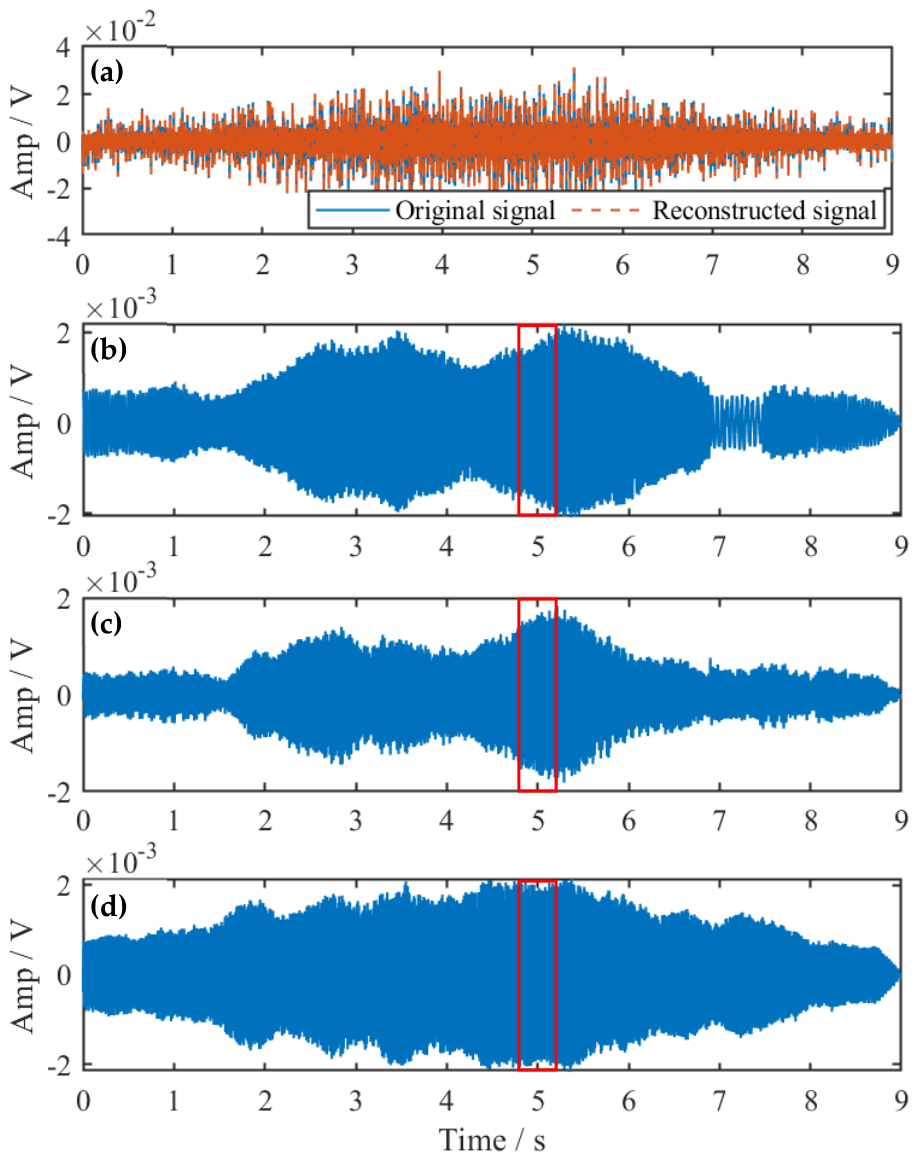
Figure 18a compares the original signal waveform with the reconstructed signal waveform using the proposed CDACT. It is shown that the signal waveform is accurately captured and reproduced by the proposed algorithm. Figure 18b–d show the time waveforms of the three major signal components in the CDACT result (Figure 17f) according to mode decomposition using Equation (36). Furthermore, the frequency spectra of the windowed signal segments (i.e., the window width 0.6 s, centered at 5 s), as shown in Figure 18, are presented in Figure 19. The result confirms that the proposed CDACT can effectively capture the characteristic defect frequencies for an accurate bearing fault diagnosis.
Figure 18.
(a) A comparison of the time waveform between the origin and the reconstructed signals using CDACT, and the time waveforms of the three decomposed major components. (b) . (c) . (d) .
Figure 19.
The frequency spectra of the windowed signal segments [4.7 s, 5.3 s] of Figure 17: (a) . (b) . (c) .
3.4. A Published Bearing Defect Signal Under Varying Speed Conditions
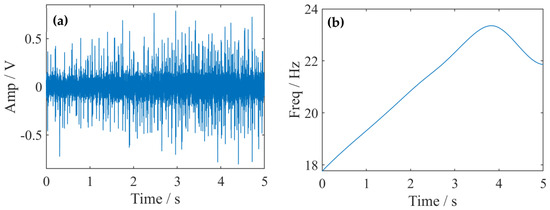
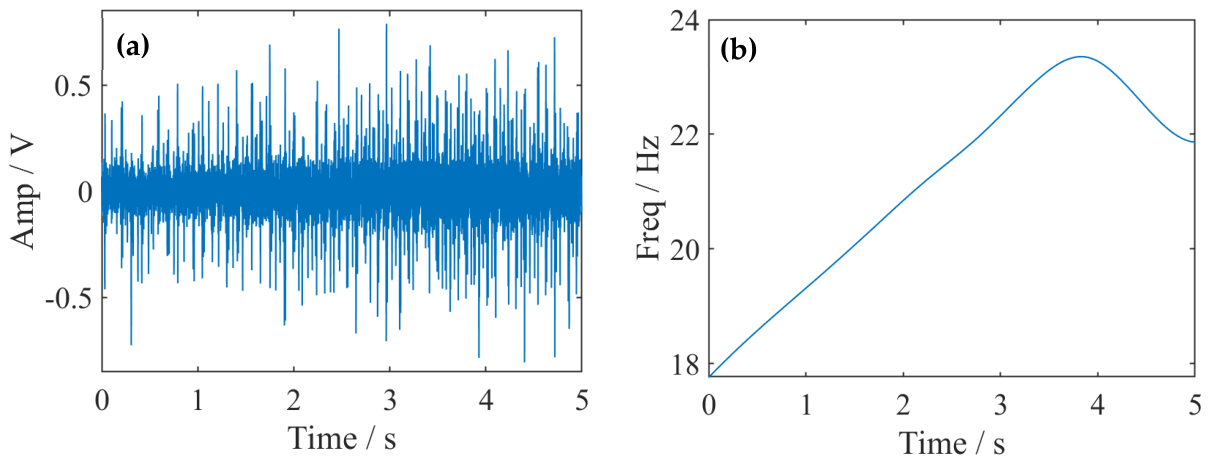
Published varying speed bearing defect data from University of Ottawa, Canada [33], is utilized in the analysis presented in this subsection. The sampling frequency used in the data acquisition was 200 kHz, and the recoding length for each data point was 10 s. During data recording, the shaft rotating frequency rose from 14.1 Hz to 23.5 Hz and then went back to 18.0 Hz within 10 s. Only a 5-s signal segment comprising a speed-increasing part and a speed-decreasing part, as shown in Figure 20 for the inner race fault signal under the badge I-C-2 dataset, was chosen in this analysis. The characteristic frequency of the bearing inner race fault was . As shown in the speed profile of Figure 20b, the shaft-rotating frequency for the signal segment increased from 17.76 Hz to 23.5 Hz and then reduced back to 21.86 Hz.
Figure 20.
(a) The time waveform. (b) The shaft-rotating speed profile.
The TFRs of the signal using the above-mentioned algorithms are compared in Figure 21. It is shown that the proposed CDACT algorithm can produce the most energy-concentrated TFR for an accurate diagnosis of the bearing fault compared to the others.
Figure 21.
Time–frequency results: (a) STFT, (b) SST, (c) ASDT, (d) EMCT, (e) PCT, and (f) CDACT.
4. Discussion
The simulation and experimental results demonstrate that, compared with the existing time–frequency analysis algorithms, the proposed algorithm has better performance in the analysis of strong time-varying FM signals in terms of both energy concentration and spectral clarity. Meanwhile, it was also shown that by incorporating the designated boundary constraint scheme, the extraction accuracy of critical feature parameters such as IFs can be effectively enhanced, which leads to a more stable and reliable output using the proposed algorithm.
5. Conclusions
This paper presented a chirp-rate-driven adaptive window Chirplet transform (CDACT) for the analysis of strong time-varying nonlinear FM signals with uncorrelated components. In this approach, the adaptive window length is determined by the instantaneous chirp rate (CR) of each signal component, and the CR at the center point of each sliding window is used to represent the demodulation rate of the window in the transform, whilst the window length between the neighboring signal components in the transform is determined by linear interpolation between the components. The effectiveness of the proposed algorithm was evaluated using both simulated and experimental signals. A comparison study showed that the proposed algorithm can produce a better IF and mode amplitude estimation for accurate fault diagnosis under strong time-varying nonstationary conditions than other commonly employed time–frequency techniques.
Author Contributions
Z.L.: Writing—original draft, methodology, investigation, formal analysis, validation. G.Y.: Methodology, visualization, supervision. T.R.L.: Conceptualization, writing—review and editing, supervision, project administration, funding acquisition. All authors have read and agreed to the published version of the manuscript.
Funding
Financial support for this work from Beijing Nature Science Foundation (IS24076) and the Ministry of Science and Technology of China through the 111 project (D21017) is grateful acknowledged.
Data Availability Statement
Data will be made available upon request.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this paper:
| STFT | Short-time Fourier transform |
| IF | Instantaneous frequency |
| CM | Condition monitoring |
| ASDT | Adaptive synchronous demodulation transform |
| CT | Chirplet transform |
| CR | Chirp rate |
| TFR | Time–frequency result |
| GLCT | Generalized linear chirplet transform |
| EMCT | Entropy-matching chirplet transform |
| ASTFT | Adaptive short-time Fourier transform |
| SNR | Signal-to-noise ratio |
References
- Villa, L.F.; Reñones, A.; Perán, J.R.; de Miguel, L.J. Statistical fault diagnosis based on vibration analysis for gear test-bench under nonstationary conditions of speed and load. Mech. Syst. Signal Process. 2012, 29, 436–446. [Google Scholar] [CrossRef] [Scilit]
- Guo, J.; Shi, Z.; Li, H.; Zhen, D.; Gu, F.; Ball, A.D. Transient impulses enhancement based on adaptive multi-scale improved differential filter and its application in rotating machines fault diagnosis. ISA Trans. 2022, 120, 271–292. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, K.; Yu, G.; Lu, Y.; Lin, T.R. A parameterized iterative synchrosqueezing transform for the analysis of noise contaminated non-stationary signals. Measurement 2023, 216, 112934. [Google Scholar] [CrossRef] [Scilit]
- Ma, Y.; Yu, G.; Lin, T.; Sun, M. A high resolution time frequency analysis technique based on bi-directional squeezing and its application in fault diagnosis of rotating machinery. ISA Trans. 2024, 147, 382–402. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Griffin, D.; Lim, J. Signal estimation from modified short-time Fourier transform. IEEE Trans. Acoust. Speech Signal Process. 1984, 32, 236–243. [Google Scholar] [CrossRef] [Scilit]
- Rioul, O.; Duhamel, P. Fast algorithms for discrete and continuous wavelet transforms. IEEE Trans. Inf. Theory 1992, 38, 569–586. [Google Scholar] [CrossRef] [Scilit]
- Stockwell, R.G.; Mansinha, L.; Lowe, R.P. Localization of the complex spectrum: The S transform. IEEE Trans. Signal Process. 1996, 44, 998–1001. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Liu, Y.; Wang, T.; Chu, F.; Peng, Z. Adaptive synchronous demodulation transform with application to analyzing multicomponent signals for machinery fault diagnostics. Mech. Syst. Signal Process. 2023, 191, 110208. [Google Scholar] [CrossRef] [Scilit]
- Mann, S.; Haykin, S. The chirplet transform: Physical considerations. IEEE Trans. Signal Process. 1995, 43, 2745–2761. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yan, Z.; Jiao, J.; Xu, Y. Adaptive linear chirplet synchroextracting transform for time-frequency feature extraction of non-stationary signals. Mech. Syst. Signal Process. 2024, 220, 111700. [Google Scholar] [CrossRef] [Scilit]
- Zhao, D.; Wang, H.; Cui, L. Frequency-chirprate synchrosqueezing-based scaling chirplet transform for wind turbine nonstationary fault feature time–frequency representation. Mech. Syst. Signal Process. 2024, 209, 111112. [Google Scholar] [CrossRef] [Scilit]
- Yu, G.; Zhou, Y. General linear chirplet transform. Mech. Syst. Signal Process. 2016, 70–71, 958–973. [Google Scholar] [CrossRef] [Scilit]
- He, Y.; Hu, M.; Jiang, Z.; Feng, K.; Ming, X. Local maximum synchrosqueezes from entropy matching chirplet transform. Mech. Syst. Signal Process. 2022, 181, 109476. [Google Scholar] [CrossRef] [Scilit]
- Guan, Y.; Liang, M.; Necsulescu, D.-S. Velocity synchronous linear chirplet transform. IEEE Trans. Ind. Electron. 2019, 66, 6270–6280. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Wang, T.; Chu, F.; Feng, Z. Component matching chirplet transform via frequency-dependent chirp rate for wind turbine planetary gearbox fault diagnostics under variable speed condition. Mech. Syst. Signal Process. 2021, 161, 107997. [Google Scholar] [CrossRef] [Scilit]
- Peng, Z.K.; Meng, G.; Chu, F.L.; Lang, Z.Q.; Zhang, W.M.; Yang, Y. Polynomial chirplet transform with application to instantaneous frequency estimation. IEEE Trans. Instrum. Meas. 2011, 60, 3222–3229. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Peng, Z.K.; Meng, G.; Zhang, W.M. Spline-kernelled chirplet transform for the analysis of signals with time-varying frequency and its application. IEEE Trans. Ind. Electron. 2012, 59, 1612–1621. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Wang, T.; Chu, F.; Han, Q.; Qin, Z.; Zuo, M.J. Scaling-basis chirplet transform. IEEE Trans. Ind. Electron. 2020, 68, 8777–8788. [Google Scholar] [CrossRef] [Scilit]
- Wu, H.; Zhi, S.; Fang, Q.; Liu, Y.; Wang, T.; Cheng, W.; Wang, Y. Adaptive sparse matching squeezing chirplet transform for multi-component time-frequency feature extraction of non-stationary signals in rotating machinery fault diagnosis. Mech. Syst. Signal Process. 2026, 256, 114463. [Google Scholar] [CrossRef] [Scilit]
- Wu, H.; Zhi, S.; Fang, Q.; Liu, Y.; Cheng, W. Adaptive matching squeezing chirplet transform for fault diagnosis of wind turbine planetary gearbox under non-stationary conditions. ISA Trans. 2025, 167, 1364–1385. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Pei, S.C.; Huang, S.G. Adaptive STFT With Chirp-Modulated Gaussian Window. In Proceedings of the 2018 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP), Calgary, AB, Canada, 15–20 April 2018; pp. 4354–4358. [Google Scholar]
- Czarnecki, K.; Fourer, D.; Auger, F.; Rojewski, M. A fast time-frequency multi-window analysis using a tuning directional kernel. Signal Process. 2018, 147, 110–119. [Google Scholar] [CrossRef] [Scilit]
- Yu, G.; Yu, M.; Xu, C. Synchroextracting transform. IEEE Trans. Ind. Electron. 2017, 64, 8042–8054. [Google Scholar] [CrossRef] [Scilit]
- Zhong, J.; Huang, Y. Time-frequency representation based on an adaptive short-time Fourier transform. IEEE Trans. Signal Process. 2010, 58, 5118–5128. [Google Scholar] [CrossRef] [Scilit]
- Rainio, O.; Hällilä, J.; Teuho, J.; Klén, R. Methods for estimating full width at half maximum. Signal Image Video Process. 2025, 19, 289. [Google Scholar] [CrossRef] [Scilit]
- Kumar, A.; Xiang, J. Robust adaptive ridge detection for frequency tracking in heavy-noise environment. Adv. Eng. Inform. 2025, 68, 103774. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Geng, C.; Zuo, M.J.; Liang, X. Use of vibration signal to estimate instantaneous angular frequency under strong nonstationary regimes. Mech. Syst. Signal Process. 2023, 200, 110571. [Google Scholar] [CrossRef] [Scilit]
- He, X.; Ding, J.; Wang, X.; Zhang, Q.; Zhao, W.; Wang, K. Adaptive extraction of characteristic ridges from time-frequency representation for wheelset bearings failure diagnosis under time-varying speed. Measurement 2025, 242, 115987. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Yang, Y.; Chen, Y.; Chen, Z. Iterative characteristic ridge extraction for bearing fault detection under variable rotational speed conditions. ISA Trans. 2022, 119, 172–183. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Meignen, S.; Pham, D.-H.; McLaughlin, S. On demodulation, ridge detection, and synchrosqueezing for multicomponent signals. IEEE Trans. Signal Process. 2017, 65, 2093–2103. [Google Scholar] [CrossRef] [Scilit]
- Yu, G.; Wang, Z.; Zhao, P.; Li, Z. Local maximum synchrosqueezing transform: An energy-concentrated time-frequency analysis tool. Mech. Syst. Signal Process. 2019, 117, 537–552. [Google Scholar] [CrossRef] [Scilit]
- Behera, R.; Meignen, S.; Oberlin, T. Theoretical analysis of the second-order synchrosqueezing transform. Appl. Comput. Harmon. Anal. 2018, 45, 379–404. [Google Scholar] [CrossRef] [Scilit]
- Huang, H.; Baddour, N. Bearing vibration data collected under time-varying rotational speed conditions. Data Brief 2018, 21, 1745–1749. [Google Scholar] [CrossRef] [Scilit] [PubMed]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.