


Abstract
In the present investigation, we introduce a new subclass of univalent functions and a subclass of bi-univalent function with bounded boundary and bounded radius rotation. Some examples of the functions belonging to the classes are also derived. For these new classes, the authors derive many interesting relations between these classes and the existing familiar subclasses in the literature. Furthermore, the authors establish new coefficient estimates for these classes. Apart from the above, the first two initial coefficient bounds for the class are established.
1. Introduction, Motivations and Definitions
Let consist of all holomorphic functions normalized by and Let be the class of all functions defined by
which are analytic and univalent in . A domain is called as starlike with respect to a point if the line segment joining to every other point lies entirely in D. A function is called starlike if is a starlike domain with respect to the origin. The class of univalent starlike functions is denoted by . A domain is called as convex if the line segment joining any two arbitrary points of D lies entirely in D, i.e., if it is starlike with respect to each point of D. A function is said to be convex in if is a convex domain. The class of all univalent convex functions is denoted by . Many times the analytic criteria of the above two functions provide a useful technique in analyzing the concepts and are as follows: a function is called as a starlike function of order if and only if
The family of all starlike functions of order is denoted by It is clear that for , Also, for , A function is called as a convex function of order if and only if
The family of all convex functions of order is denoted by It is clear that for , A function of the form (1) is called as a close-to-convex function if there exists a function such that
The family of all close-to-convex functions is denoted by Although the class of close-to-convex functions was introduced by Kaplan [1] in 1952, Ozaki [2] introduced the class familiarly known as the Ozaki-close-to-convex function, which is defined as follows: a function G given in the form (1) belongs to the class if G satisfies the condition
or
We observe that follows from the original definition of Kaplan [1], while Umezawa [3] proved that functions in are not necessarily starlike but are convex in one direction. Singh and Singh [4] proved that functions in are close-to-convex and bounded in Let denote the class of locally univalent normalized analytic functions f in the unit disk, satisfying the condition
for some If ; then, Also, The functions of the class are known to be univalent and close-to-convex in Note that the class plays an important role in determining the univalence criteria for sense-preserving harmonic mappings. The functions of the class are non-empty because it is very easy to see that the function , defined by
belongs to the class
The family of all Ozaki-type close-to-convex functions denoted by is defined as:
Definition 1.
For more details, one may see [5,6,7] and also [8,9]. Paatero [10] introduced the class of functions with bounded turning. If a function satisfies then there exists a non-decreasing function with bounded variation in and satisfying
such that
Connection between the class and the class of functions with positive real part is stated in the following lemma that has been established earlier by Pinchuk [11].
Lemma 1.
A function if and only if ∃ such that
A function if and only if there exists a function such that
The class was introduced and investigated by Padmanabhan and Parvatham [12]. A function that is analytic and locally univalent in a given simply connected domain is said to be of bounded boundary rotation if its range has bounded boundary rotation, which is defined as the total variation in the direction angle of the tangent to the boundary curve under a complete circuit. Let denote the family of functions G that map the unit disc conformally onto an image domain of bounded boundary rotation at most
Umarani [13] introduced class functions of bounded boundary rotation of complex order We say a function , where b is a non-zero complex number if
Umarani [13] showed that a function if and only if there exists a function such that
For the choice of b, the class reduces to the following important subclasses
- (i)
- For , , and the well-known class of functions of bounded boundary rotation at most was introduced by Paatero [10].
- (ii)
- For we have , introduced by Padmanabhan and Parvatham [12].
A function is said to be in the class the class of functions with bounded radius rotations (introduced by Tammi [14]), if for
The integral representation for functions is given by
where is a non-decreasing function with bounded variation in and satisfying
Pinchuk [11] showed that an Alexander-type relation between the classes and exists and is given by
Lehto [15] (see [16]) proved that for the function given in the form (1)
Following the work of Brannan [18], who proved that is a subclass of the class of the close-to-convex functions of order , Koepf [19] showed that is a subclass of the class of the k-fold symmetric close-to-convex functions of order . This leads to the solution to the coefficient problem for k-fold symmetric functions of bounded boundary rotation when . Moreover, for , consists of close-to-convex functions and, hence, are univalent functions. Further, Leach [20] investigated the concept of odd univalent functions with bounded boundary rotation, and this was extended to k-fold symmetric functions by the same author a little later in the same year, and for details, one may look at [21].
The Koebe one-quarter theorem [22] ensures that the image of under every univalent function contains a disk of radius Thus, every univalent function G has an inverse , satisfying
and
The inverse may have an analytic continuation to , where
where
A function is called as bi-univalent in if both G and its inverse belong to the class Indicate to be the family of all bi-univalent functions in . The family is non-empty as the functions , and are in the family . It is interesting that the famous Koebe function does not belong to the family The family of bi-univalent functions was investigated for the first time by Lewin [23], who obtained a non-sharp bound . This was followed by Brannan and Clunie [18] and Brannan and Taha [24], who worked on certain subclasses of the bi-univalent functions and obtained bounds for their initial coefficients. The study of bi-univalent functions gained concentration as well as thrust mainly due to the investigation of Srivastava et al. [25] and was followed by many authors.
In the current article, we introduce Ozaki-type close-to-convex functions with bounded boundary rotation denoted by . Examples showing that the class is non-empty are discussed. The authors also derive many interesting connections between the class and and . Finally, a new subclass of bi-univalent functions with bounded boundary and bounded radius rotation is introduced. For the class , the authors obtain interesting first two initial non-sharp coefficient bounds.
2. Ozaki Close-to-Convex Functions with Bounded Boundary Rotation
We start this section by introducing a new class of Ozaki-type close-to-convex functions with bounded boundary rotation and is defined as follows.
Definition 2.
Let and A function G given in the form (1) is called as Ozaki-type close-to-convex with bounded boundary rotation if G satisfies the following condition
The family of all Ozaki-type close-to-convex functions with bounded boundary rotation is denoted by
Remark 1.
(i) If then , which consists of functions of bounded boundary rotation introduced in [11].
- (ii)
- If then consists of Ozaki-type close-to-convex functions.
- (iii)
- If and then , which consists of convex functions introduced in [26].
Here, we show that the class is non-empty by providing a few examples.
Examples of functions belonging to the class .
Example 1.
The function is defined by
Straightforward computations shows that
Since
Therefore, Hence, the function
Example 2.
The function is defined by
Straightforward computations shows that
Since
Therefore, Hence, the function
Example 3.
The function is defined by
Example 4.
The function is defined by
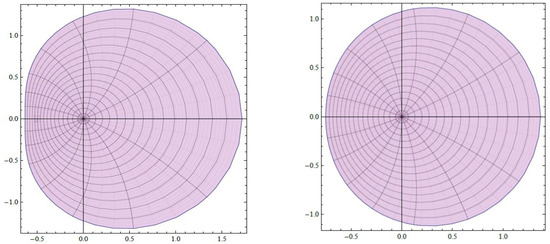
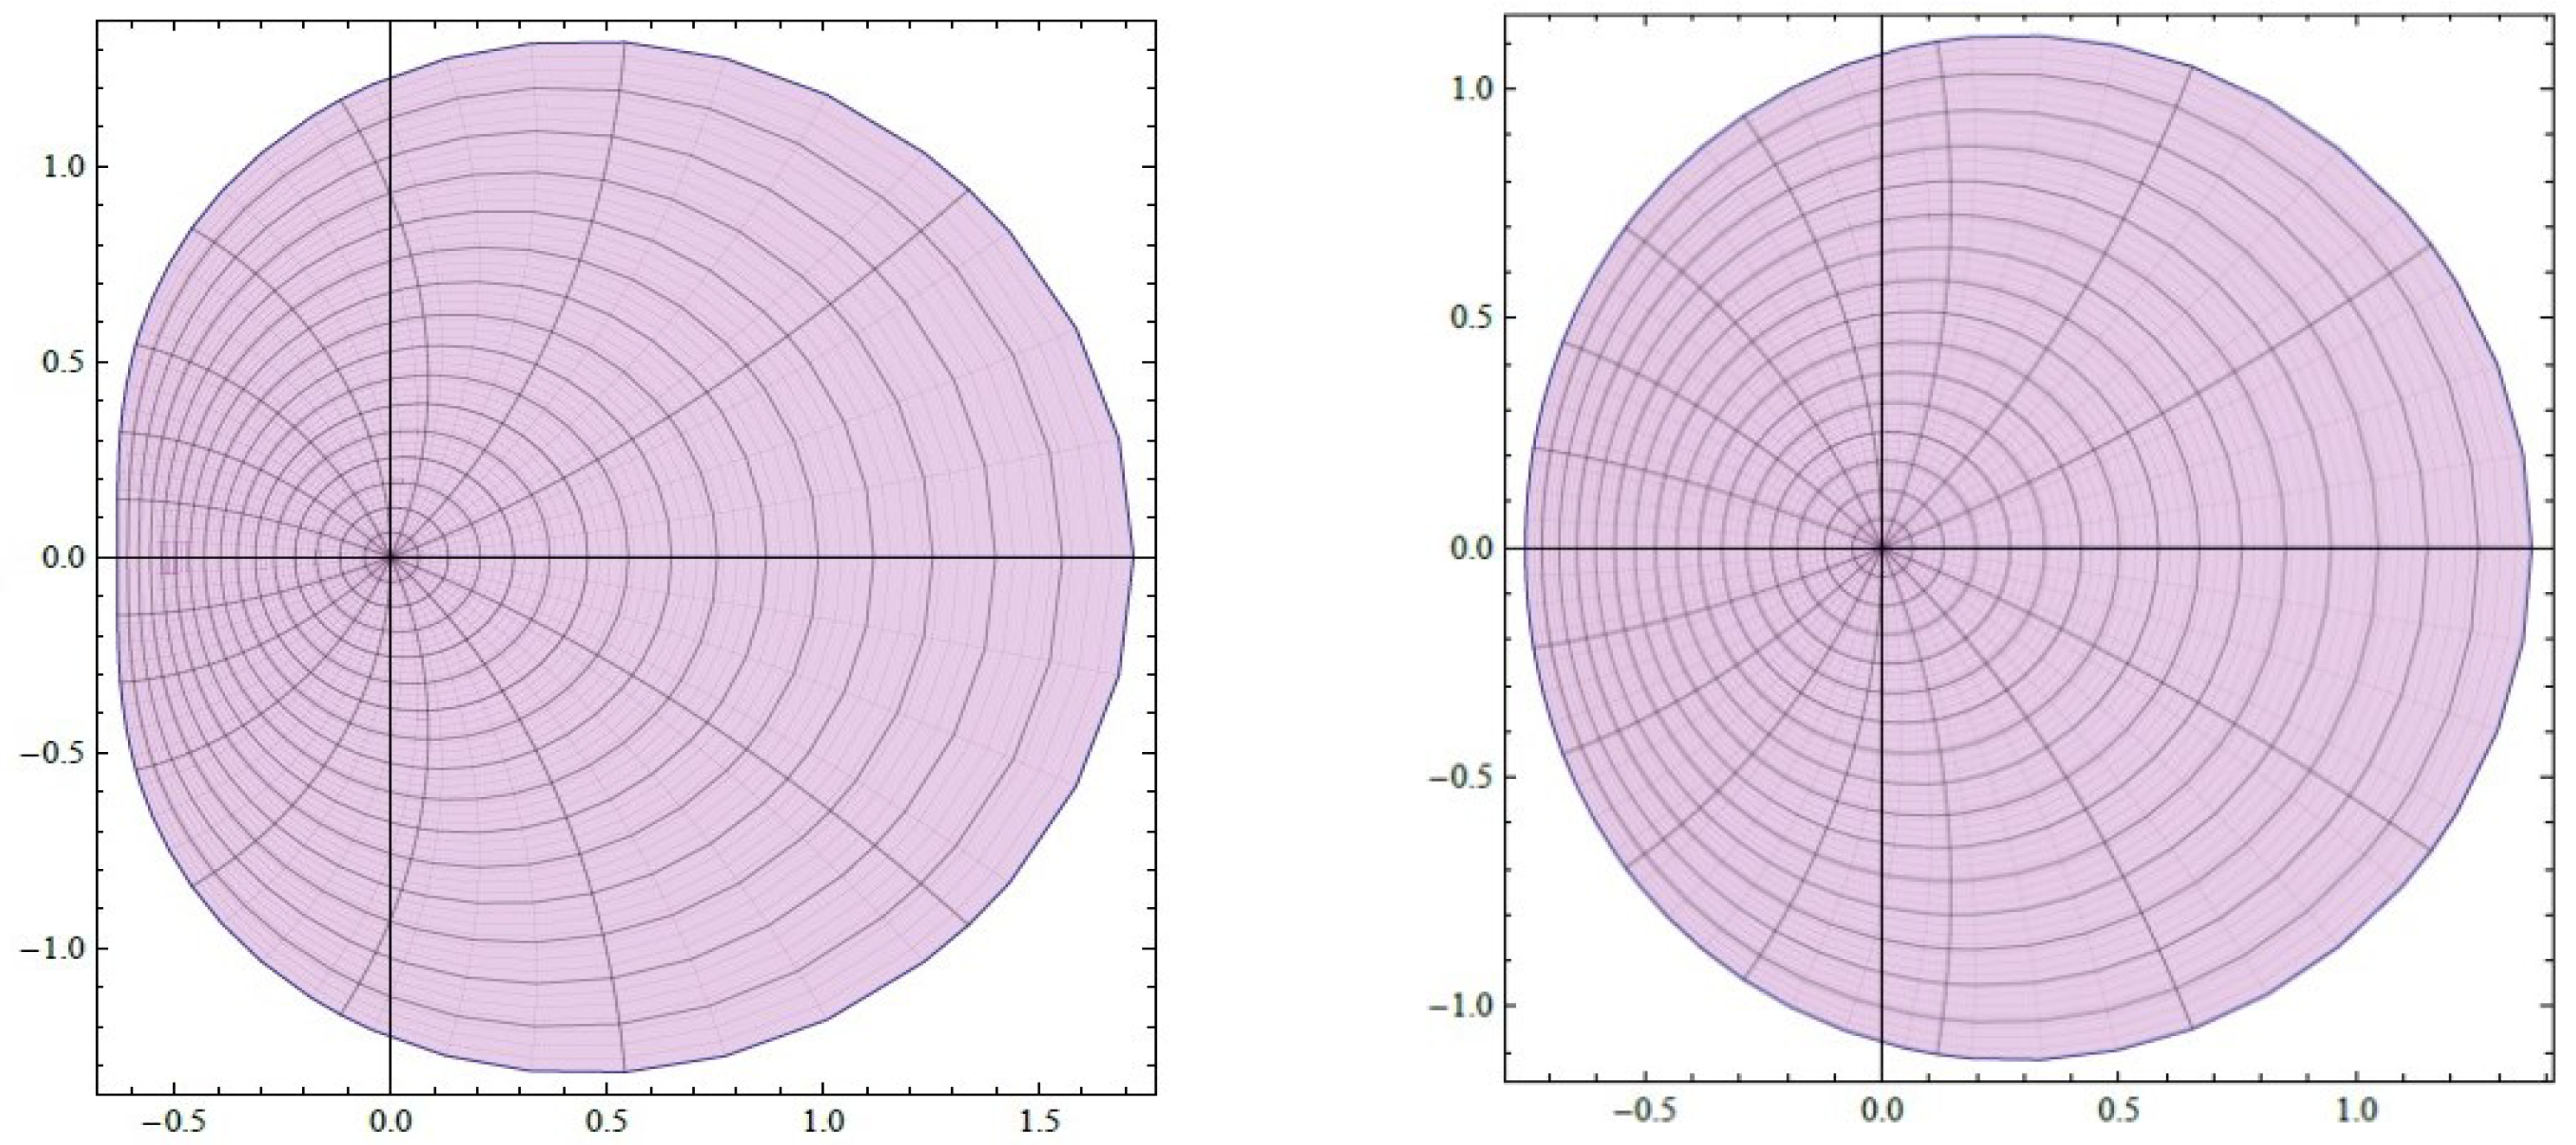
The images of the function and under unit disk are shown as below in Figure 1.
Figure 1.
Image of under for is shown in the left picture and Image of under for is shown in the right picture.
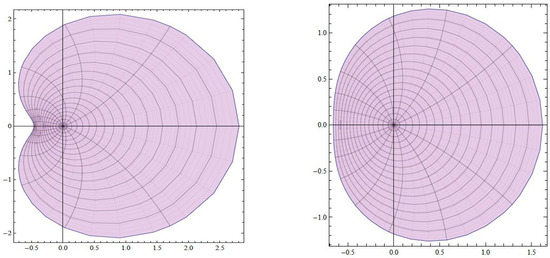
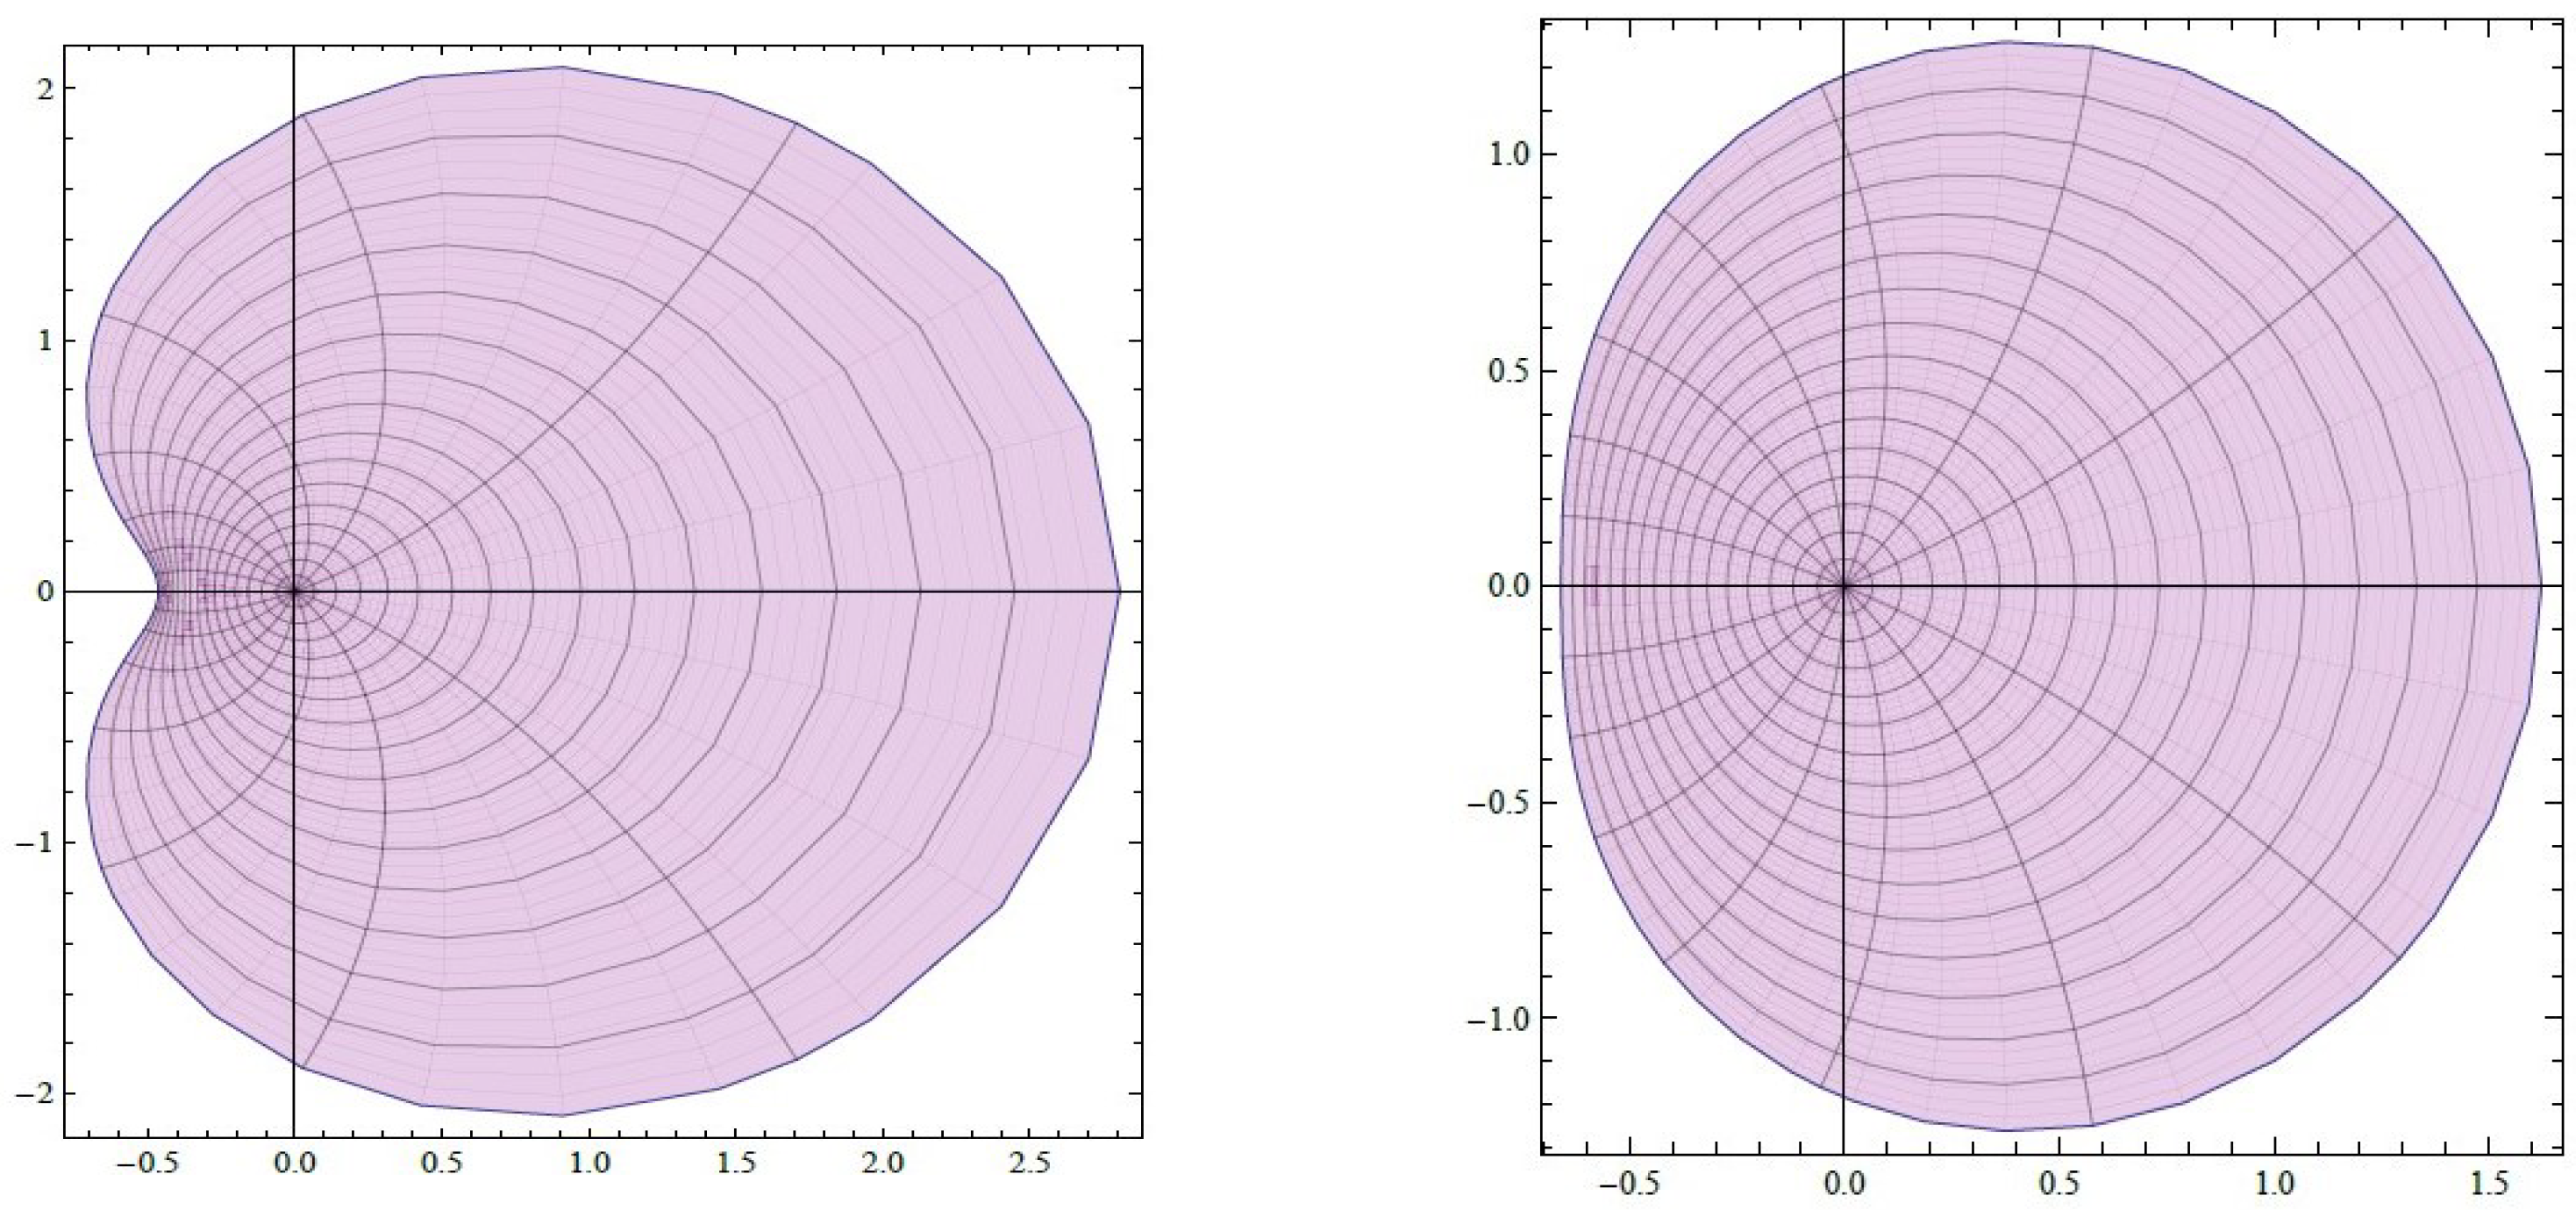
Similarly, the images of the function and under unit disk are shown as below in Figure 2.
Figure 2.
Image of under for = 0.7, u = 0.3 is shown in the left picture and Image of under for = 0.7, u = 0.3 is shown in the right picture.
Next, we prove new interesting properties of the class , stated as Theorems 1–10.
We start with proving an integral representation theorem.
2.1. Integral Representation of
Theorem 1.
If then
where ν is a non-decreasing function with bounded variation in and satisfying
Proof.
Since there exists an analytic function belonging to the class such that
Equation (9) can be written as
Since by the representation theorem given by Paatero [10], there exists a non-decreasing function with bounded variation in and satisfying
such that
Therefore,
From (10) and (11), we obtain (8). The proof of Theorem 1 is hence completed. □
2.2. Relation between and
Theorem 2.
Let and A function if ∃ a function such that
Proof.
We know that a function if and only if Hence, if and only if
From Theorem 2 and (16), we obtain the following result.
2.3. Relation between and
Theorem 3.
Let and A function if ∃ a function such that
2.4. Relation between and
Theorem 4.
Let and A function if ∃ functions such that
Proof.
Since we know that a function if and only if and , using Theorem 4, we have the following result.
2.5. Relation between and
Theorem 5.
For and A function if ∃ functions such that
Based on Equations (2)–(4), we have the following results, and they are stated by omitting the proof.
Theorem 6.
Let and A function if
- (i)
- ∃ a function such that
- (ii)
- ∃ a function such that
- (iii)
- ∃ a function such that
Theorem 7.
Let and If a function then for
Proof.
Since then from Theorem 1, we have
where is a non-decreasing function with bounded variation in and satisfying
Let us take . Then,
Since is a non-decreasing functions with bounded variation in , we can write , where both and are non-decreasing functions with bounded variation in and satisfying
Here, we can write
To prove the lower bound, it is sufficient to show that
If then and Therefore, we have
Hence, we obtain
The proof of Theorem 7 is thus finished. □
Theorem 8.
Proof.
Remark 2.
(i) For Theorem 8 verifies the bounds of and obtained by Letho [15].
- (ii)
- For Theorem 8 verifies the bound of obtained by Schiffer and Tammi [17].
Theorem 9.
If then the function defined by
also belongs to
Proof.
Since then from Theorem 2, ∃ such that
Robertson [27] showed that if then defined by
which also belongs to . Therefore, we obtain
The proof of Theorem 9 is thus completed. □
Theorem 10.
If and then G is univalent in and
Proof.
If then given in (33) belongs to By differentiating (33) with respect to and substituting we obtain
Therefore,
By using the bound of given in (25) and replacing d by we have
Equation (37) can be rewritten as
If then according to Ahlfors [28] univalence criterion, G is univalent in Equation (38) gives (36). The proof of Theorem 10 is hence finished. □
Theorem 11.
If then for , we have
3. Ozaki-Type Bi-Close-to-Convex Functions with Bounded Boundary Rotation
Definition 3.
Suppose , and A function G given by (1) is called as Ozaki-type bi-close-to-convex functions with bounded boundary rotation of order λ if the conditions
and
are satisfied. The family of all Ozaki-type bi-close-to-convex functions with bounded boundary rotation of order λ is denoted by
To prove the main results of this section, we need the following lemma.
Lemma 2.
[30] Let . If a function belongs to the class then
Theorem 12.
Proof.
Let the function Then, there exist and in such that
and
where
and
From Equations (45)–(48), we obtain
and
Hence from (49) and (51), we obtain . Again, from (50) and (52), we obtain
An application of Lemma 2 in (53) gives
Hence, (54) gives (42). Here, again from (50) and (52) and by applying (53), we obtain
An application of Lemma 2 in (55) gives (43). Hence, for any and by using (53) and (55), we have
Here, using triangle inequality and an application of Lemma 2 in (56) implies
Hence, (57) gives (44). The proof of Theorem 12 is thus finished. □
For the choice , the class reduces to the class Hence, we obtain the following result for the functions belonging to the class , which verifies the bound of and obtained by Tezelcı and Sümer Eker [6].
Corollary 1.
Let Then, the class reduces to the class , which denotes the class of all bi-convex functions with the bounded boundary rotation of order Hence, we obtain the following result for the functions belonging to the class , which verifies the bound obtained by (Li et al. [31], Corollary 3.2).
Corollary 2.
Remark 3.
Corollary 2 verifies the results obtained by (Sharma et al. [32] Corollary 7).
4. Concluding Remarks and Observations
In the current article, we introduced a new subclass of univalent functions with bounded boundary rotation. Many interesting examples are constructed for the class Interesting connections between the class and the familiar classes of starlike, convex and convex functions of bounded boundary rotation and starlike functions of bounded radius rotation are obtained. Following the interesting connection, the first three coefficient bounds for the new subclass were derived. Furthermore, the authors also introduced a new subclass of bi-univalent functions associated with bounded boundary rotation. For the new class , the authors obtained new initial two coefficient estimates. Apart from the new interesting coefficient estimates, the established coefficient estimates also generalize the earlier existing results.
Finally, the study considered in this article can be extended by taking different types of convolution operators existing in the literature. Also, similar types of results can be investigated for interesting special functions.
Author Contributions
Conceptualization: A.A., S.S. and S.M.E.-D.; original draft preparation: P.S. and S.S.; writing—review and editing: A.A., S.S. and S.M.E.-D.; investigation: A.A., S.S. and S.M.E.-D. All authors have read and agreed to the published version of the manuscript.
Funding
This research received the financial support from the Deanship of Graduate Studies and Scientific Research at Qassim University (QU-APC-2024-9/1).
Data Availability Statement
Data is contained within the article.
Acknowledgments
The authors would like to thank the referees for many useful corrections and opinions on the original version of the manuscript. The researchers would like to thank the Deanship of Graduate Studies and Scientific Research at Qassim University for financial support (QU-APC-2024-9/1).
Conflicts of Interest
The authors declare no conflicts of interest.
Correction Statement
This article has been republished with a minor correction to the Acknowledgments. This change does not affect the scientific content of the article.
References
- Kaplan, W. Close-to-convex schlicht functions. Mich. Math. J. 1952, 1, 169–185. [Google Scholar] [CrossRef] [Scilit]
- Ozaki, S. On the theory of multivalent functions. II. Sci. Rep. Tokyo Bunrika Daigaku. Sect. A 1941, 4, 45–87. [Google Scholar]
- Umezawa, T. Analytic functions convex in one direction. J. Math. Soc. Jpn. 1952, 4, 194–202. [Google Scholar] [CrossRef] [Scilit]
- Singh, R.; Singh, S. Some sufficient conditions for univalence and starlikeness. Colloq. Math. 1982, 47, 309–314. [Google Scholar] [CrossRef] [Scilit]
- Srivastava, H.M.; Rath, B.; Sanjay Kumar, K.; Vamshee Krishna, D. Some sharp bounds of the third-order Hankel determinant for the inverses of the Ozaki type close-to-convex functions. Bull. Sci. Math. 2023, 191, 103381. [Google Scholar] [CrossRef] [Scilit]
- Tezelcı, M.; Sümer Eker, S. On strongly Ozaki bi-close-to-convex functions. Turk. J. Math. 2019, 43, 862–870. [Google Scholar] [CrossRef] [Scilit]
- Vijaya, K.; Murugusundaramoorthy, G.; Breaz, D.; Oros, G.I.; El-Deeb, S.M. Ozaki-Type Bi-Close-to-Convex and Bi-Concave Functions Involving a Modified Caputo’s Fractional Operator Linked with a Three-Leaf Function. Fractal Fract. 2024, 8, 220. [Google Scholar] [CrossRef] [Scilit]
- Thomas, D.K.; Tuneski, N.; Vasudevarao, A. Univalent Functions; De Gruyter Studies in Mathematics; De Gruyter: Berlin, Germany, 2018; Volume 69. [Google Scholar]
- Vasudevarao, A.; Thomas, D.K.; Tuneski, N. On Ozaki close-to-convex functions. Bull. Aust. Math. Soc. 2019, 99, 89–100. [Google Scholar]
- Paatero, V. Über die konforme Abbildung mehrblättriger Gebiete von beschränkter Randdrehung. Ann. Acad. Sci. Fenn. Ser. AI Math.-Phys. 1933, 37, 9p. [Google Scholar]
- Pinchuk, B. Functions of bounded boundary rotation. Isr. J. Math. 1971, 10, 6–16. [Google Scholar] [CrossRef] [Scilit]
- Padmanabhan, K.S.; Parvatham, R. Properties of a class of functions with bounded boundary rotation. Ann. Polon. Math. 1976, 31, 311–323. [Google Scholar] [CrossRef] [Scilit]
- Umarani, P.G. Functions of bounded boundary rotation of complex order. Math. Balk. 1989, 3, 34–43. [Google Scholar]
- Tammi, O. On the maximalization of the coefficients of schlicht and related functions. Ann. Acad. Sci. Fenn. Ser. AI Math.-Phys. 1952, 114, 51p. [Google Scholar]
- Lehto, O.E. On the distortion of conformal mappings with bounded boundary rotation. Ann. Acad. Sci. Fenn. Ser. AI Math.-Phys. 1952, 124, 14. [Google Scholar]
- Thomas, D.K. On the coefficients of functions with bounded boundary rotation. Proc. Am. Math. Soc. 1972, 36, 123–129. [Google Scholar] [CrossRef]
- Schiffer, M.M.; Tammi, O. On the fourth coefficient of univalent functions with bounded boundary rotation. Ann. Acad. Sci. Fenn. Ser. AI Math.-Phys. 1967, 396, 1–26. [Google Scholar] [CrossRef] [Scilit]
- Brannan, D.A.; Clunie, J.G. Aspects of Contemporary Complex Analysis; Academic Press, Inc.: London, UK, 1980. [Google Scholar]
- Koepf, W.A. Coefficients of symmetric functions of bounded boundary rotation. Proc. Am. Math. Soc. 1989, 105, 324–329. [Google Scholar] [CrossRef]
- Leach, R. On Odd Functions of bounded boundary rotation. Can. J. Math. 1974, 26, 551–564. [Google Scholar] [CrossRef] [Scilit]
- Leach, R. Coefficients of symmetric functions of bounded boundary rotation. Can. J. Math. 1974, 26, 1351–1355. [Google Scholar] [CrossRef] [Scilit]
- Duren, P.L. Univalent functions. In Grundlehren der Mathematischen Wissenschaften; Springer: New York, NY, USA, 1983; Volume 259. [Google Scholar]
- Lewin, M. On a coefficient problem for bi-univalent functions. Proc. Am. Math. Soc. 1967, 18, 63–68. [Google Scholar] [CrossRef]
- Brannan, D.A.; Taha, T.S. On Some Classes of Bi-Univalent Functions, in Mathematical Analysis and Its Applications KUWAIT; KFAS Proceedings Series; Pergamon: Oxford, UK, 1985; Volume 3, pp. 53–60. [Google Scholar]
- Srivastava, H.M.; Mishra, A.K.; Gochhayat, P. Certain subclasses of analytic and bi-univalent functions. Appl. Math. Lett. 2010, 23, 1188–1192. [Google Scholar] [CrossRef] [Scilit]
- Robertson, M.S. On the theory of univalent functions. Ann. Math. 1936, 37, 374–408. [Google Scholar] [CrossRef] [Scilit]
- Robertson, M.S. Coefficients of functions with bounded boundary rotation. Can. J. Math. 1969, 21, 1477–1482. [Google Scholar] [CrossRef] [Scilit]
- Ahlfors, L.V. Sufficient Conditions for Quasiconformal Extension. Ann. Math. Stud. 1973, 79, 23–29. [Google Scholar]
- Brannan, D.A. On functions of bounded boundary rotation I. Proc. Edinb. Math. Soc. 1969, 16, 339–347. [Google Scholar] [CrossRef] [Scilit]
- Alkahtani, B.S.T.; Goswami, P.; Bulboacă, T. Estimate for initial MacLaurin coefficients of certain subclasses of bi-univalent functions. Miskolc Math. Notes 2016, 17, 739–748. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Vijaya, K.; Murugusundaramoorthy, G.; Tang, H. On new subclasses of bi-starlike functions with bounded boundary rotation. AIMS Math. 2020, 5, 3346–3356. [Google Scholar] [CrossRef] [Scilit]
- Sharma, P.; Sivasubramanian, S.; Cho, N.E. Initial coefficient bounds for certain new subclasses of bi-univalent functions with bounded boundary rotation. AIMS Math. 2023, 8, 29535–29554. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).