


Abstract
We introduce a matrix-valued fractional delay differential system in diverse cases and present Fox type stability results with applications of aggregated special functions. In addition we present an example showing the numerical solutions based on the second type Kudryashov method. Finally, via the method of variation of constants, and some properties of the parametric Mittag–Leffler matrices, we obtain both symmetric random and symmetric fuzzy finite-time stability results for the governing fractional delay model. A numerical example is considered to illustrate applicability of the study.
1. Introduction
Generally fractional-order equations are considered as an extension of ODEs, and they have been used as more appropriate models of real-world issues in physics, engineering, finance, etc. [1,2]. The applications of fractional-order calculus have been growing, including petroleum engineering, viscoelastic mechanics, anomalous diffusion, multi-strain tuberculosis model, control system, and many other branches of engineering and physics [3,4]. A good collection of diverse fractional-order models used to mechanics, viscoelasticity, thermodiffusion, and thermodynamics is given in [5]. In different processes, like technical processes, chemical processes, economics, biosciences, a delay is observed. With the combination of both time delay and fractional derivative, the subject of fractional-order delay differential models is enjoying growing interest among scientists [6,7,8,9,10,11].
Finite-time stability is a notion that was first presented in the 1950s. This notion differs from classical stability [12,13] in two significant ways. First, finite-time stability requires prescribed bounds on system variables. Second, it deals with systems whose operation is limited to a fixed finite interval of time. For systems that are known to operate only over a finite interval of time and whenever, from specific considerations, the systems’ variables must lie within particular bounds, finite-time stability is the only meaningful description of stability [14,15,16].
Motivated by [17,18], we consider the Caputo fractional delay differential system below:
where is the Caputo derivative with t is a fixed delay time, for
Let be a square matrix of for every We shall investigate the cases below:
- Case 1:
- and
- Case 2:
- and
- Case 3:
- and
- Case 4:
- and
In Case (1), we study Fox type stability results with applications of aggregation maps and special functions. Finally, a numerical method is applied to find the approximate solutions. In Case (2), via the method of variation of constants, and some properties of the delayed one parameter Mittag–Leffler matrix, we investigate the explicit formula of solutions. Thereafter, we propose symmetric random finite-time stability results. In Case (3), by the method of variation of constants, and some properties of the delayed two parameter Mittag–Leffler matrix, we study the explicit formula of solutions. In Case (4), through the delayed Mittag–Leffler matrices in one and two parameters, we prove symmetric fuzzy finite-time stability for the above fractional-order delay system. Next, a numerical example is considered to illustrate applicability of the study.
2. Preliminaries
2.1. Special Functions
2.1.1. Fox Type Functions
In this part, we present the Fox -function and its variations (see [19]).
The Fox -function introduced by Charles Fox (1961) is defined as follows:
where and
in which an empty product is interpreted as 1, and the integers satisfy the inequalities and . Let the coefficients
and the complex parameters
be constrained s.t. no poles of the integrand in (3) coincide, and is a suitable contour of the Mellin–Barnes type (in the complex S-plane) which has one of the forms below:
- is a left loop beginning at and terminating at , enclosing all the poles of
- is a left loop beginning at and terminating at , enclosing all the poles of , situated in a horizontal strip beginning at the point and ending at the point with and
- is a contour beginning at the point and ending at the point , for every
Plus, if,
then, the integral in (3) converges absolutely and defines the -function that is analytic in the sector:
and with the point being tacitly excluded. Indeed, the -function makes sense and also presents an analytic function of when either
or
We now propose the special cases of Fox’s -function as follows:
- Exponential function:
- One parameter Mittag–Leffler function:
- Gauss Hypergeometric function:
- Wright function:
- Fox–Wright function:
Consider the positive vectors and complex vectors and The Fox–Wright function is given by the series
where
and
The series (4) has a nonzero radius of convergence if
Plus, if , then, the series converges for all finite values of and if , its radius of convergence equals
The convergence on the boundary , however, depends on the value of
by noting that series (4) converges absolutely for if
- Meijer -function:
Note that an empty product in (9) is defined to be one, and the poles
of the gamma functions and the poles
of the gamma functions do not coincide, that is
Besides, is one of the contours given above that separate all poles in (10) on the left from all poles in (11) on the right of .
- -function:
For we define
If and then, this function (13) can be represented in terms of the Mellin–Barnes integral of the following form
where and with the special contour
2.1.2. Mittag–Leffler Type Functions
We introduce a novel Mittag–Leffler function with m-parameters as follows [20]:
Suppose and The m-parameter function of the Mittag–Leffler type is given by
where with for every and Note that the generalized Pochhammer symbol is defined by
We now introduce a family of parametric Mittag–Leffler type functions, as follows:
- One-parameter function of the Mittag–Leffler type:
- Two-parameter function of the Mittag–Leffler type:
- Three-parameter function of the Mittag–Leffler type:
- Four-parameter function of the Mittag–Leffler type [21]:
- Five-parameter function of the Mittag–Leffler type [22]:
2.1.3. Supertrigonometric and Superhyperbolic Mittag–Leffler Type Functions
In this part, let and We shall consider the Supertrigonometric and Superhyperbolic Mittag–Leffler type functions in one parameter, as follows [23,24,25,26,27]:
- Pre-supercosine-Mittag–Leffler-type function:
- Pre-supersine-Mittag–Leffler-type function:
- Pre-superhyperbolic supercosine-Mittag–Leffler-type function
- Pre-superhyperbolic supersine-Mittag–Leffler-type function
2.1.4. Supertrigonometric and Superhyperbolic Gauss–Hypergeometric Type Functions
Let and We shall consider the Supertrigonometric and Superhyperbolic Gauss–Hypergeometric type functions, as follows [28,29]:
- Supercosine-Gauss–Hypergeometric type function:
- Supersine-Gauss–Hypergeometric type function:
- Superhyperbolic cosine-Gauss–Hypergeometric type function:
- Superhyperbolic sine-Gauss–Hypergeometric type function:
2.2. Generalized Triangular Norms (GTNs)
Let and
with the partial order relation below:
and the bold symbols and defind by
and
Definition 1
([18]). A GTN on diagonal matrices is an operation , s.t. for every satisfies the following:
(1)
(2) ,
(3)
(4)
For every sequences , converging to respectively, if
then on diagonal matrices is continuous.
For instance, consider the continuous GTNs defined as follows:
and
If, for every GTNs and every
then, we say that is stronger than or, equivalently, is weaker than .
In the above examples, and are weaker and stronger GTNs, respectively. In other words, we get the ordering below:
Throughout the paper, we let
2.3. Symmetric Matrix Valued Fuzzy Normed Spaces
Let be a vector space and be a collection of all matrix valued fuzzy sets (in short, MVF sets), with the continuous increasing mappings , s.t. for every
In , we define the ordering below:
for every and
Definition 2
([18]). Consider the continuous GTN the vector space , and the MVF set . A symmetric matrix valued fuzzy normed space (shortly, SMVFNS) is a triple , s.t. for every and we have that
(1) ,
(2) , iff
(3) , for every ,
(4)
Note 1.
A symmetric matrix valued fuzzy Banach space (or SMVFBS) is a complete SMVFNS.
In this paper we consider the minimum GTN.
Example 1.
We prove in the following four steps that the parametric Mittag–Leffler function below defines a symmetric fuzzy norm as follows:
for every and
(1) If , then, and . Thus, is an increasing mapping, for every , and also we have that .
(2) The equality , clearly shows that , for every , and vice versa.
(3) For every and , we get
(4) Let
Thus, for every and we have that
If , we get . Thus, we have
thus, . But , and also
which implies that
Hence,
for every and Thus, is a symmtric fuzzy norm for every , and .
2.4. Symmetric Matrix Valued Random Normed Spaces
Let be a collection of all matrix valued distribution functions (shortly, MVDFs ) with the left–continuous and non–decreasing mappings s.t., and Assume that the subset contains all functions s.t., the left limit of the function at the point is
In , we define the ordering below:
for every The maximal element for in the above order is the MVDF defined as
Example 2.
The function given by
is a MVDF. Note and
Definition 3
([17]). Consider the continuous GTN , the vector space , and the DF . A symmetric matrix valued random normed space (shortly, SMVRNS) is a triple , s.t. for every and we have that
- (1)
- iff
- (2)
- for every
- (3)
- ,
where denotes the value of at a point
Example 3.
We prove in the following steps that the increasing Hypergeometric function below defines a symmetric random norm as follows:
in which and .
We can easily show that , for every , iff .
For every and , we get
Let . Then, we have that , for every and If , we have . Thus, we obtain
hence, . But , and
which implies that
Thus, we conclude that
for every and Hence, is a symmetric random norm, for every , and , where () is a normed linear space.
2.5. Caputo Fractional Derivatives
The fractional integral of order for a function can be written as follows
for every
The Riemann–Liouville derivative of order for a function is defined by
for every
The Caputo derivative of order for a function is given by
for every
2.6. Delayed Parametric Mittag–Leffler Type Matrices
We first introduce parametric Mittag–Leffler matrices and then, we define delayed parametric Mittag–Leffler matrices and some of their properties.
Definition 4
([17]). The one parameter and two parameter Mittag–Leffler matrices with parameters and square matrix are respectively defined by
and
Definition 5
([30]). Delayed one parameter and two parameter Mittag–Leffler matrices and are respectively defined as follows:
and
where I (or ) and are identity and zero matrices.
Lemma 1.
For every with and we have that
and
Proof.
Making use of (16), we get
□
Lemma 2.
For with we get
where is the Beta function.
Proof.
Using integration by parts, we have
□
Lemma 3.
For and fixed number we get
Proof.
From integration by parts, we have
□
Lemma 4.
For and fixed number we get
Proof.
Applying mathematical induction, for every and fixed number we get
- (1)
- For applying we obtain
- (2)
- For applying we obtain
- (3)
- For and we have thatFor the relation below holds:
□
Lemma 5.
For every with fixed number and we get the following items:
(i) For every and we obtain
(ii) For every with and we have
Proof.
(i) For and we get
(ii) For every and we get
□
Lemma 6.
For every with fixed number and we obtain
Proof.
□
Lemma 7.
For every and we get
Proof.
in which we apply the monotonic property of function for that infers for every □
2.7. Multiple Aggregate Window Maps
Let and An n-ary aggregation map is a mapping s.t.
and
or, equivalently, and .
Besides, for every if then,
In case for every we get
Note that denotes the arity of the aggradation map. Also, the aggregation maps will simply be written instead of .
Now, we present a small list of well-known aggregation maps as follows:
- Geometric mean functions:
- Arithmetric mean functions:
- Maximum functions:
- Minimum functions:
- Median of odd numbers:
- Median of even numbers:
- Sum functions:
- Product functions:
2.8. Second Type Kudryashov Method
Let us present the algorithm of the second type Kudryashov method, as follows:
3. Fox Type Stability of (1) for Case 1
Consider the following matrix valued Fox-type controller defined by
where and
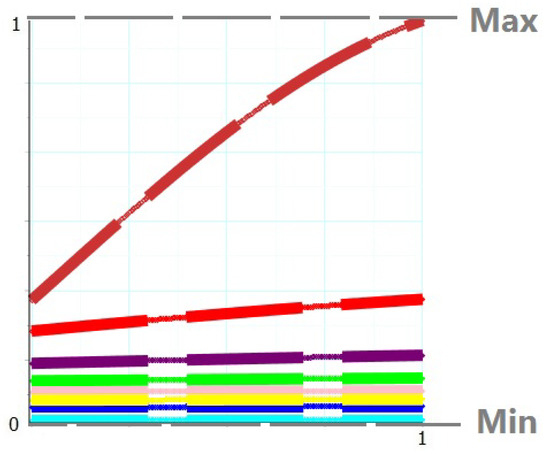
In view of (24), the plots of aggregation maps are displayed separately in Figure 1. As you can see, the minimum aggregation map , and the maximum aggregation map , include the lowest and highest values respectively, and the rest of the aggregation maps , are placed between them. Thus, we conclude that the aggregate special controller can present a better approximation for (1) than the others.
Figure 1.
The plots of aggregation maps on control function The minimum aggregation map and the maximum aggregation map are shown in cyan and brown colors, respectively, and the rest is between them.
Definition 6.
Now, consider the following matrix valued fuzzy controllers created by the Mittag–Leffler type functions, the one parameter Supertrigonometric and Superhyperbolic Mittag–Leffler type functions, and Supertrigonometric and Superhyperbolic Gauss–Hypergeometric type functions, as follows:
and
Likewise as above, we can see that the minimum aggregation maps present a better approximation for (1), than
In summary, we have the following important theorem:
Theorem 1.
Proof.
It is easy to show that the unique solution of fractional Equation (1) is given by
Plus, if is a solution of the inequality (27), then is a solution of the following inequality, for every
We prove the inequality (29) only for the special cases: one parameter of the Mittag–Leffler function and the Gauss Hypergeometric function, as follows:
and
□
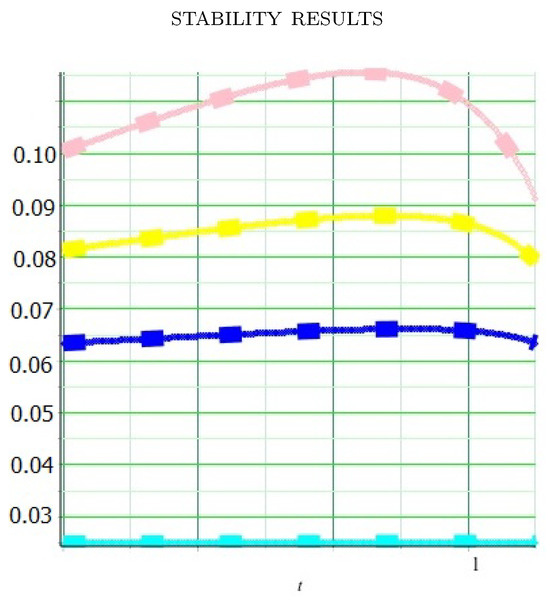
The plots of aggregation map on control special functions are displayed in Figure 2. As you can observe, the graph of the aggregate window function , can present the best estimation among the rest of the drawn control functions. Considering relation (32) and the above, we have that
Thus, fractional order Equation (1) is Fox-type stable with respect to
Figure 2.
The plots of the aggregate window functions in colors: cyan , blue , yellow , and pink .
3.1. Fractional-Order Harry Dym Equation
Consider (1), when and is a function with continuous second derivative.
Putting the above in (1), we get the following nonlinear time fractional Harry Dym equation defined by
Consider the following transformations that represent novel dependent variables below
in which and
Note that and its spatial derivative tend to zero as Then, we have that
and
Thus, (33) can be expressed as follows:
This time, apply the transformation below
Based on (35) and (37), we obtain the Korteweg–De Vries equation defined by
Define the following new variable with constant
Application of the Second Type Kudryashov Method
Balancing the highest order derivative in (40) with the nonlinear term we obtain
Let the solution of (40) be given by
where are fixed.
Based on (40) and (41), as well as (23), we obtain a system of algebraic equations, as follows:
Solving the above system, we get
From the above results, the following solution is derived as
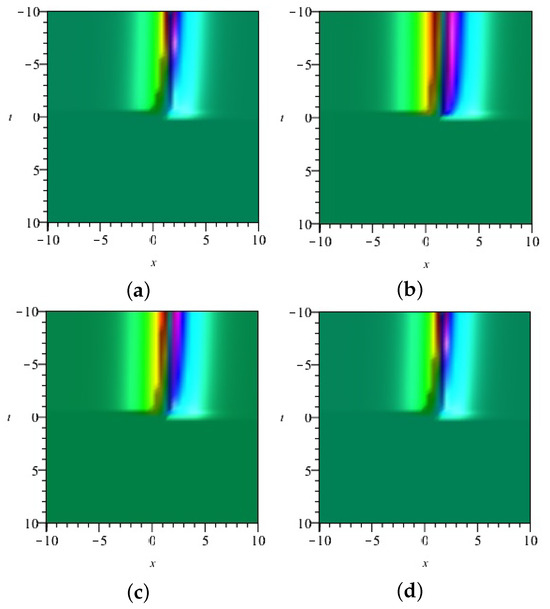
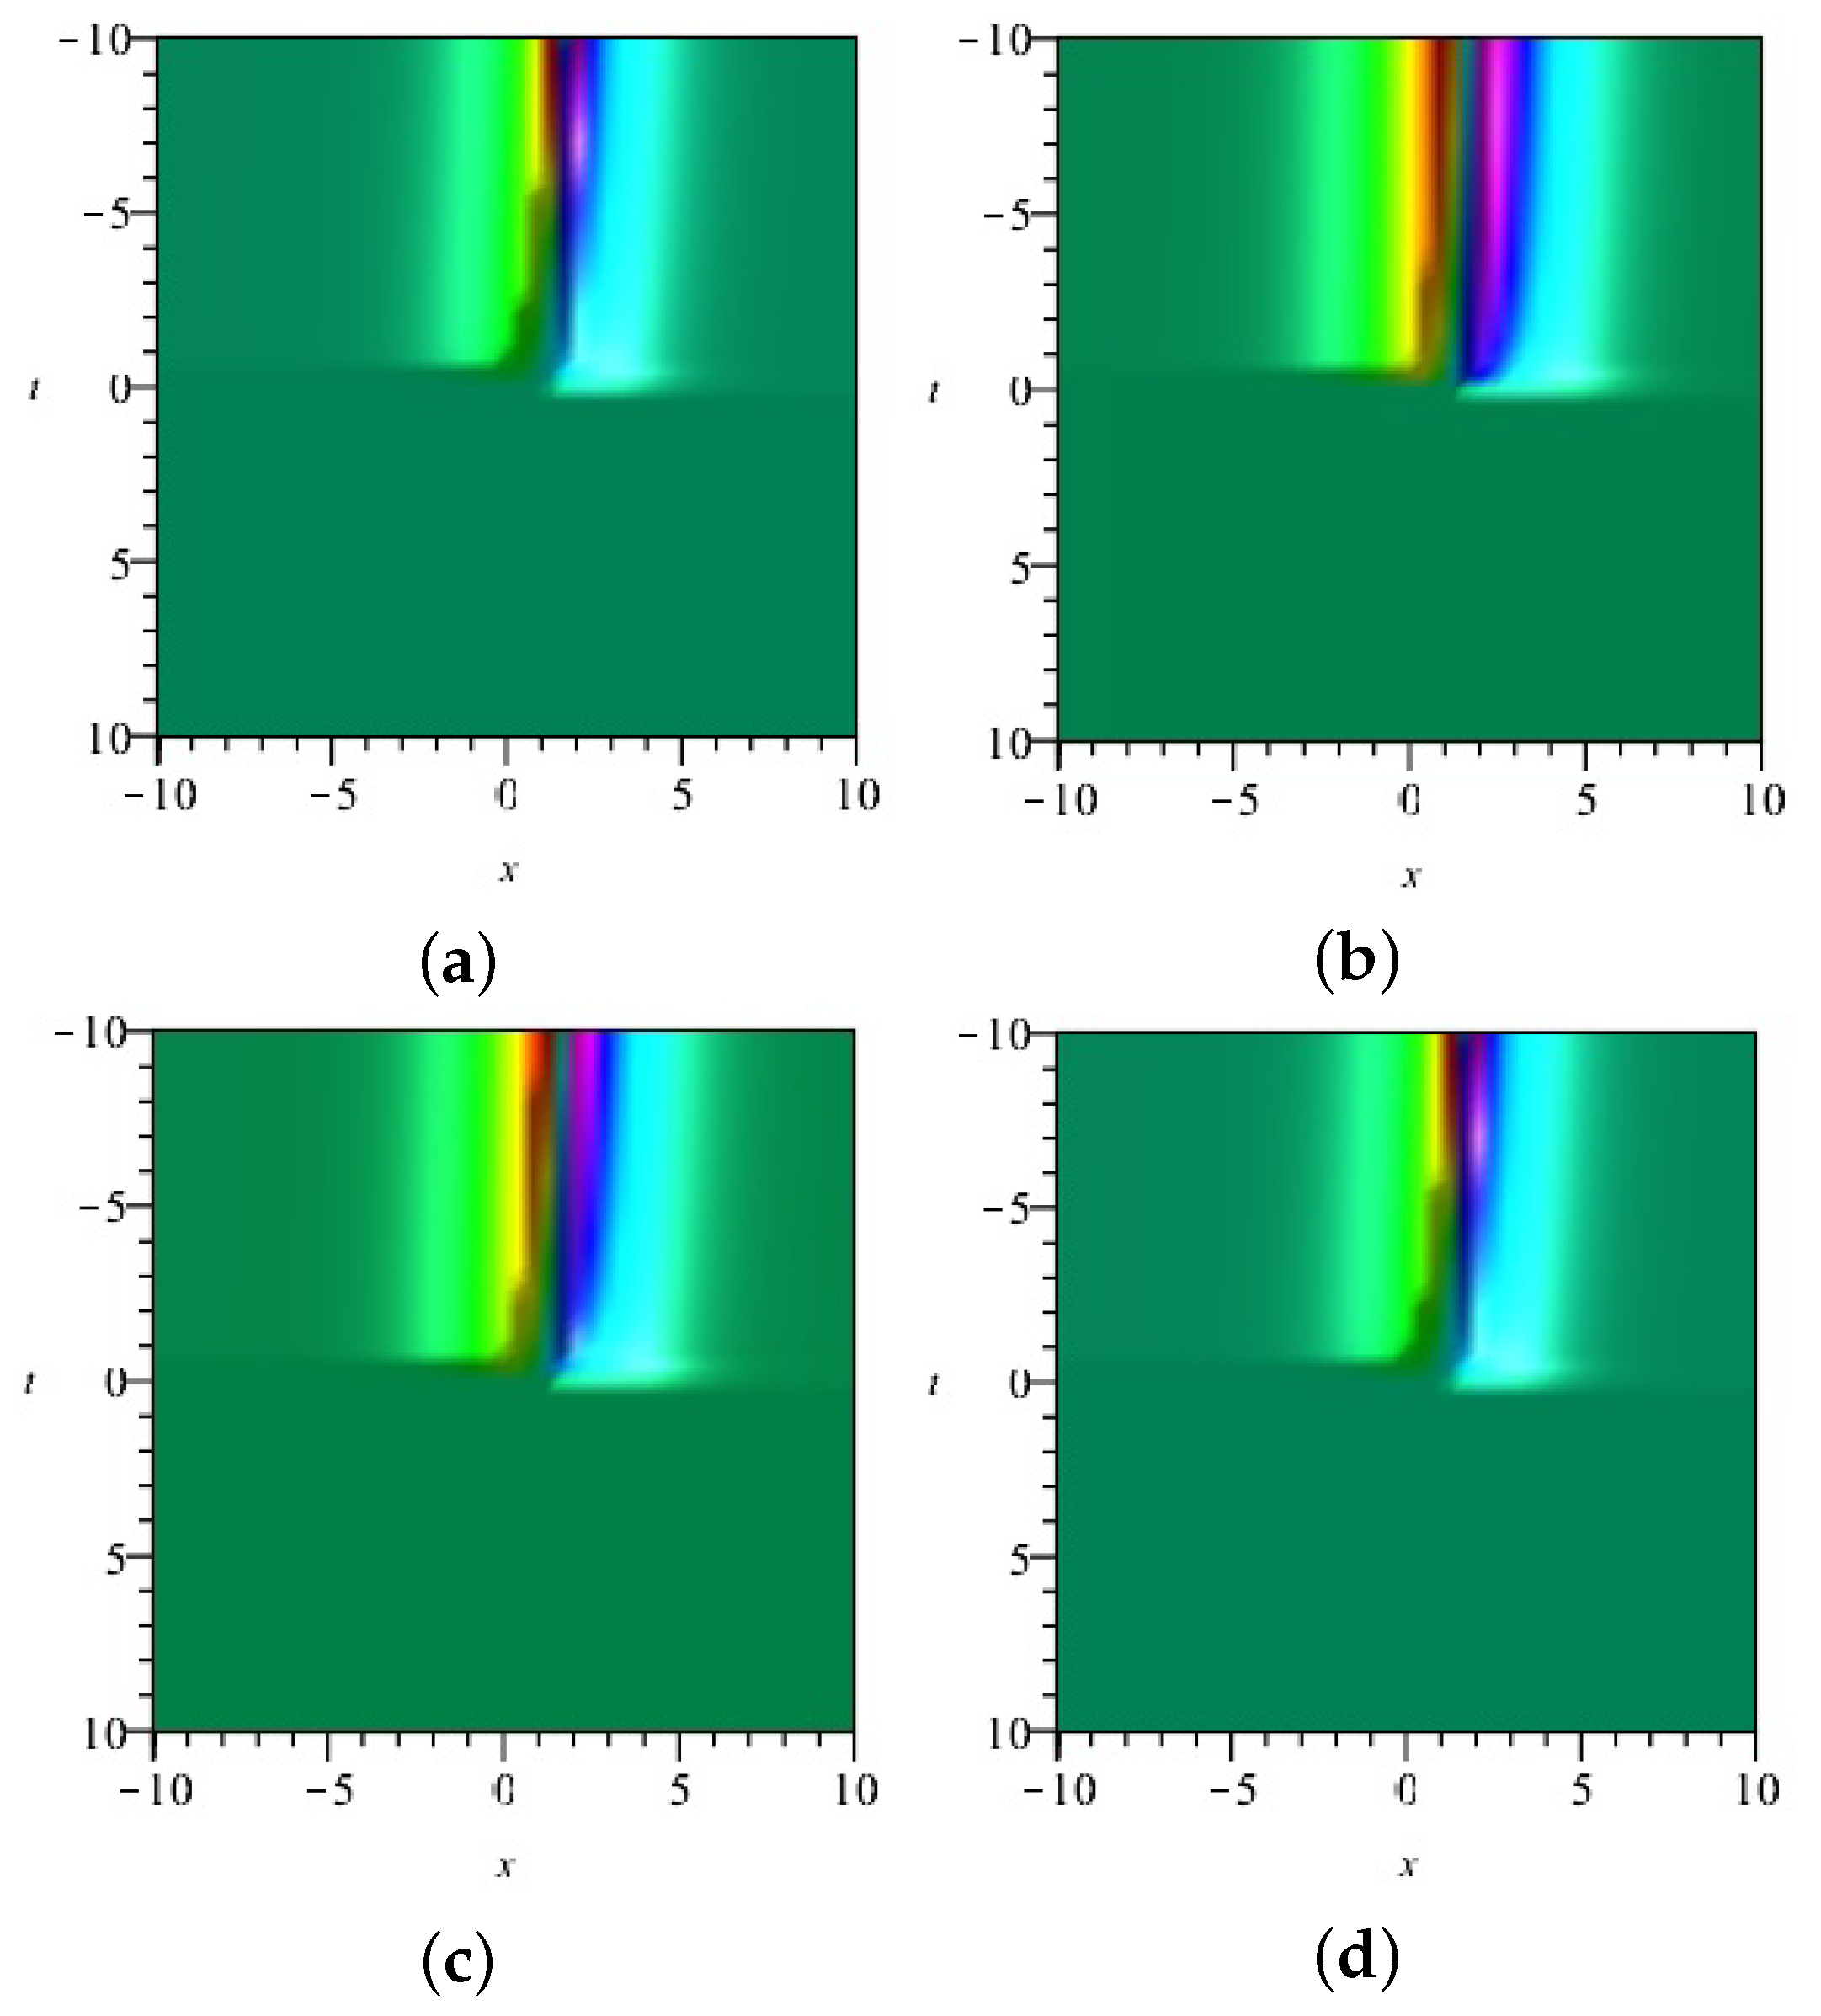
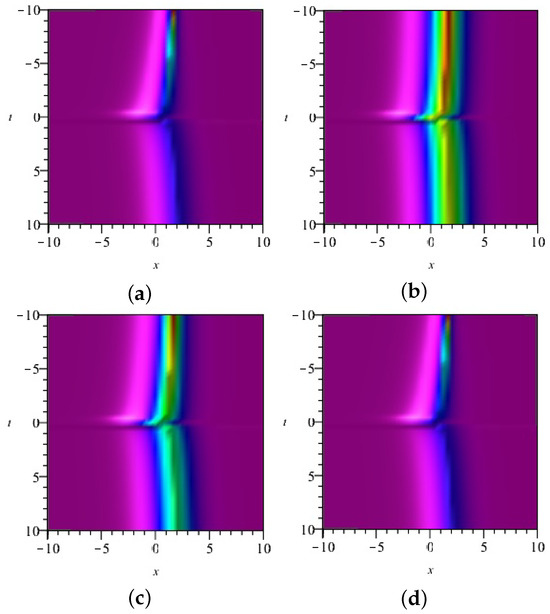
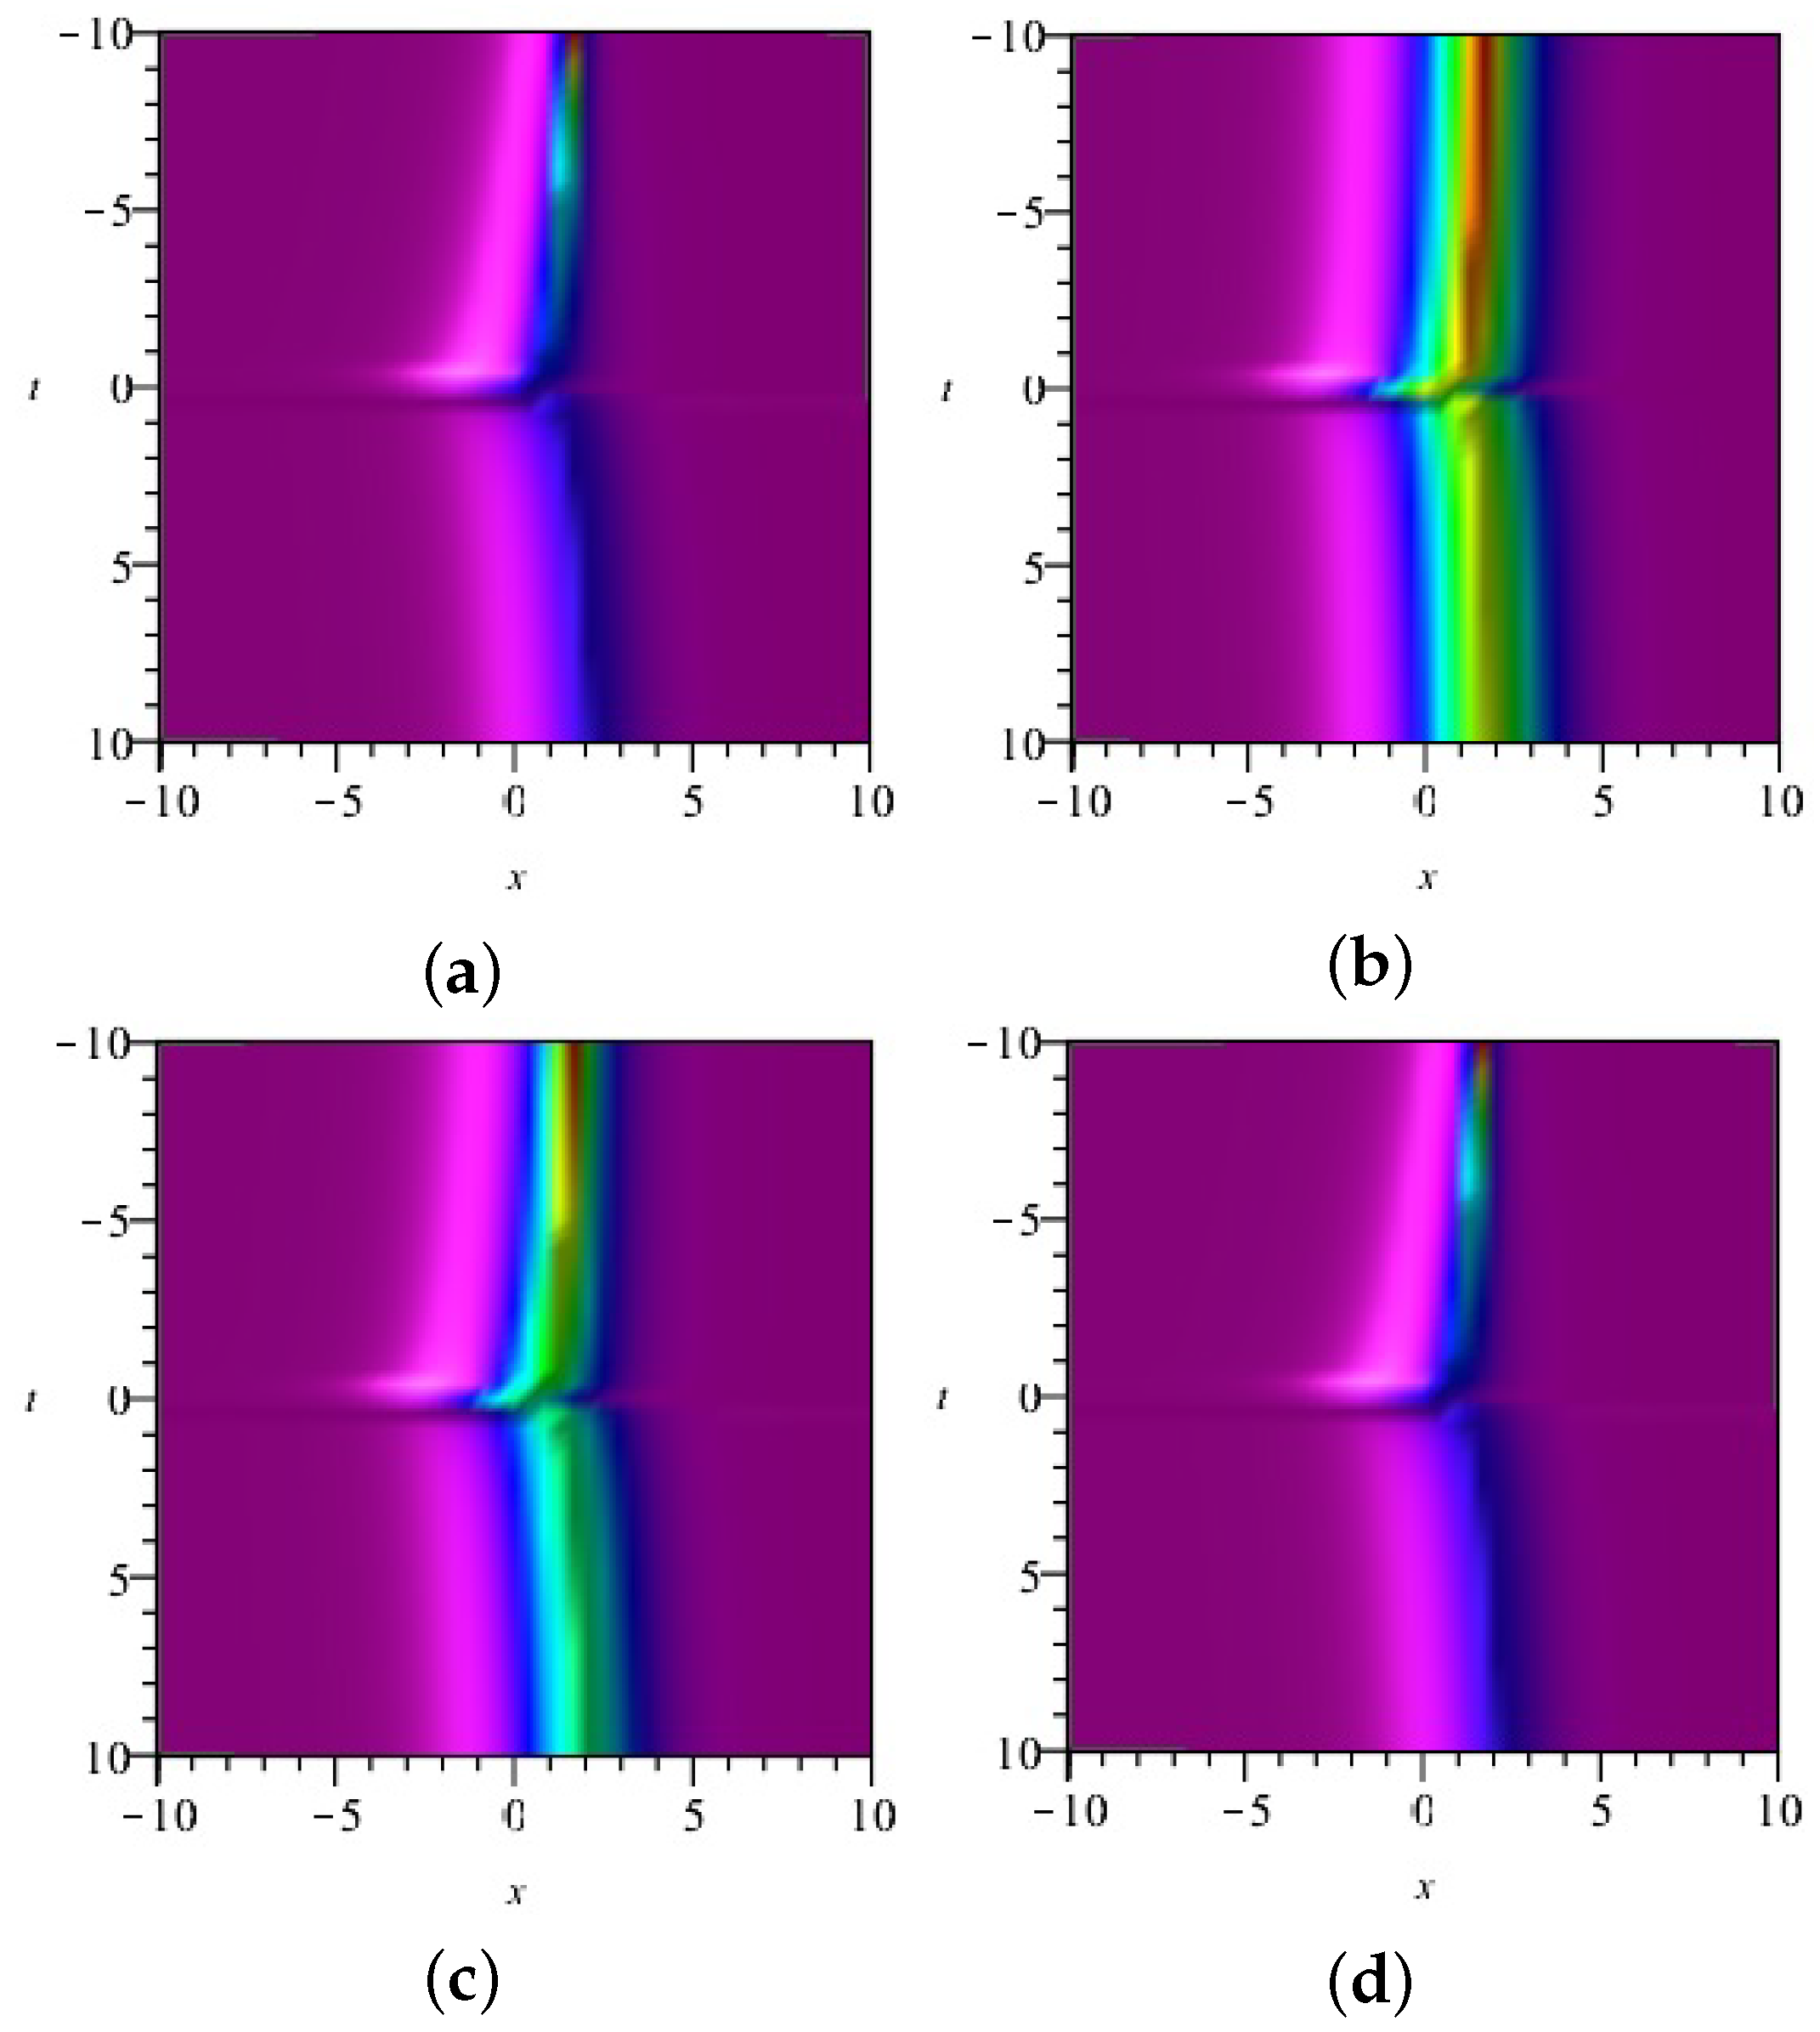
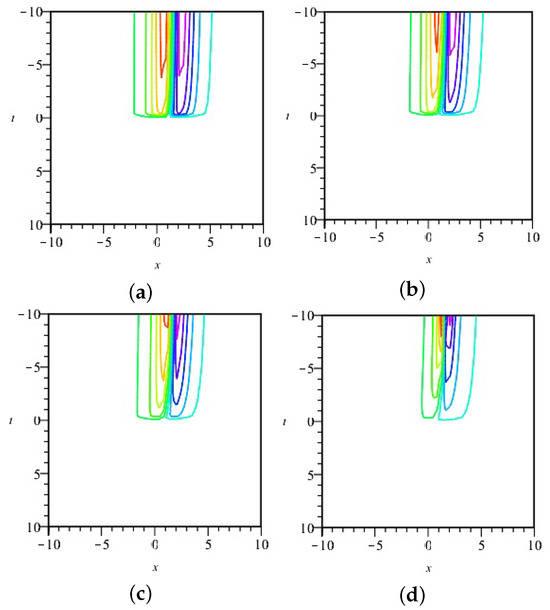
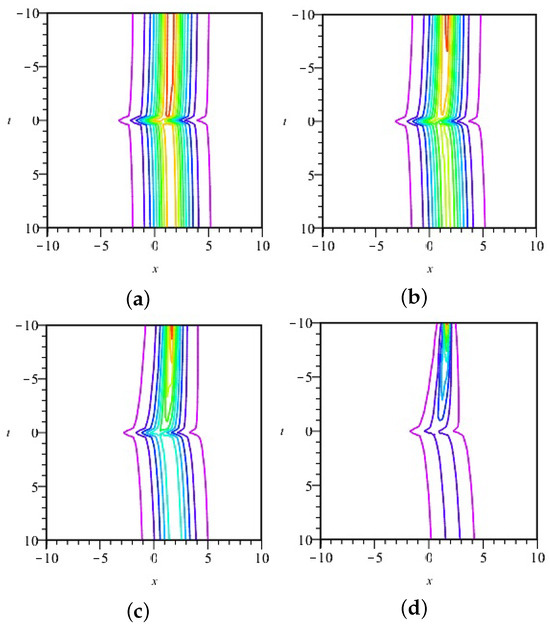
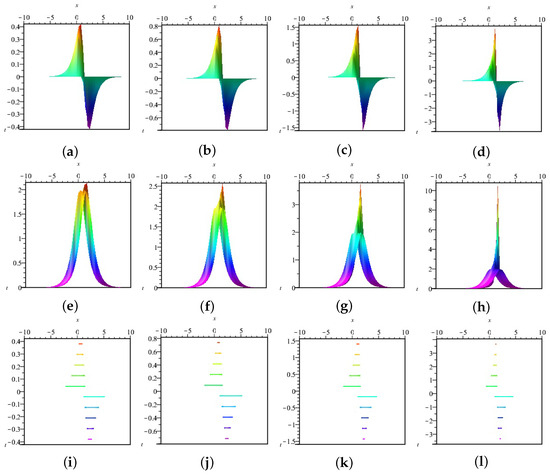
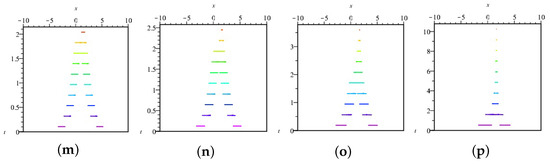
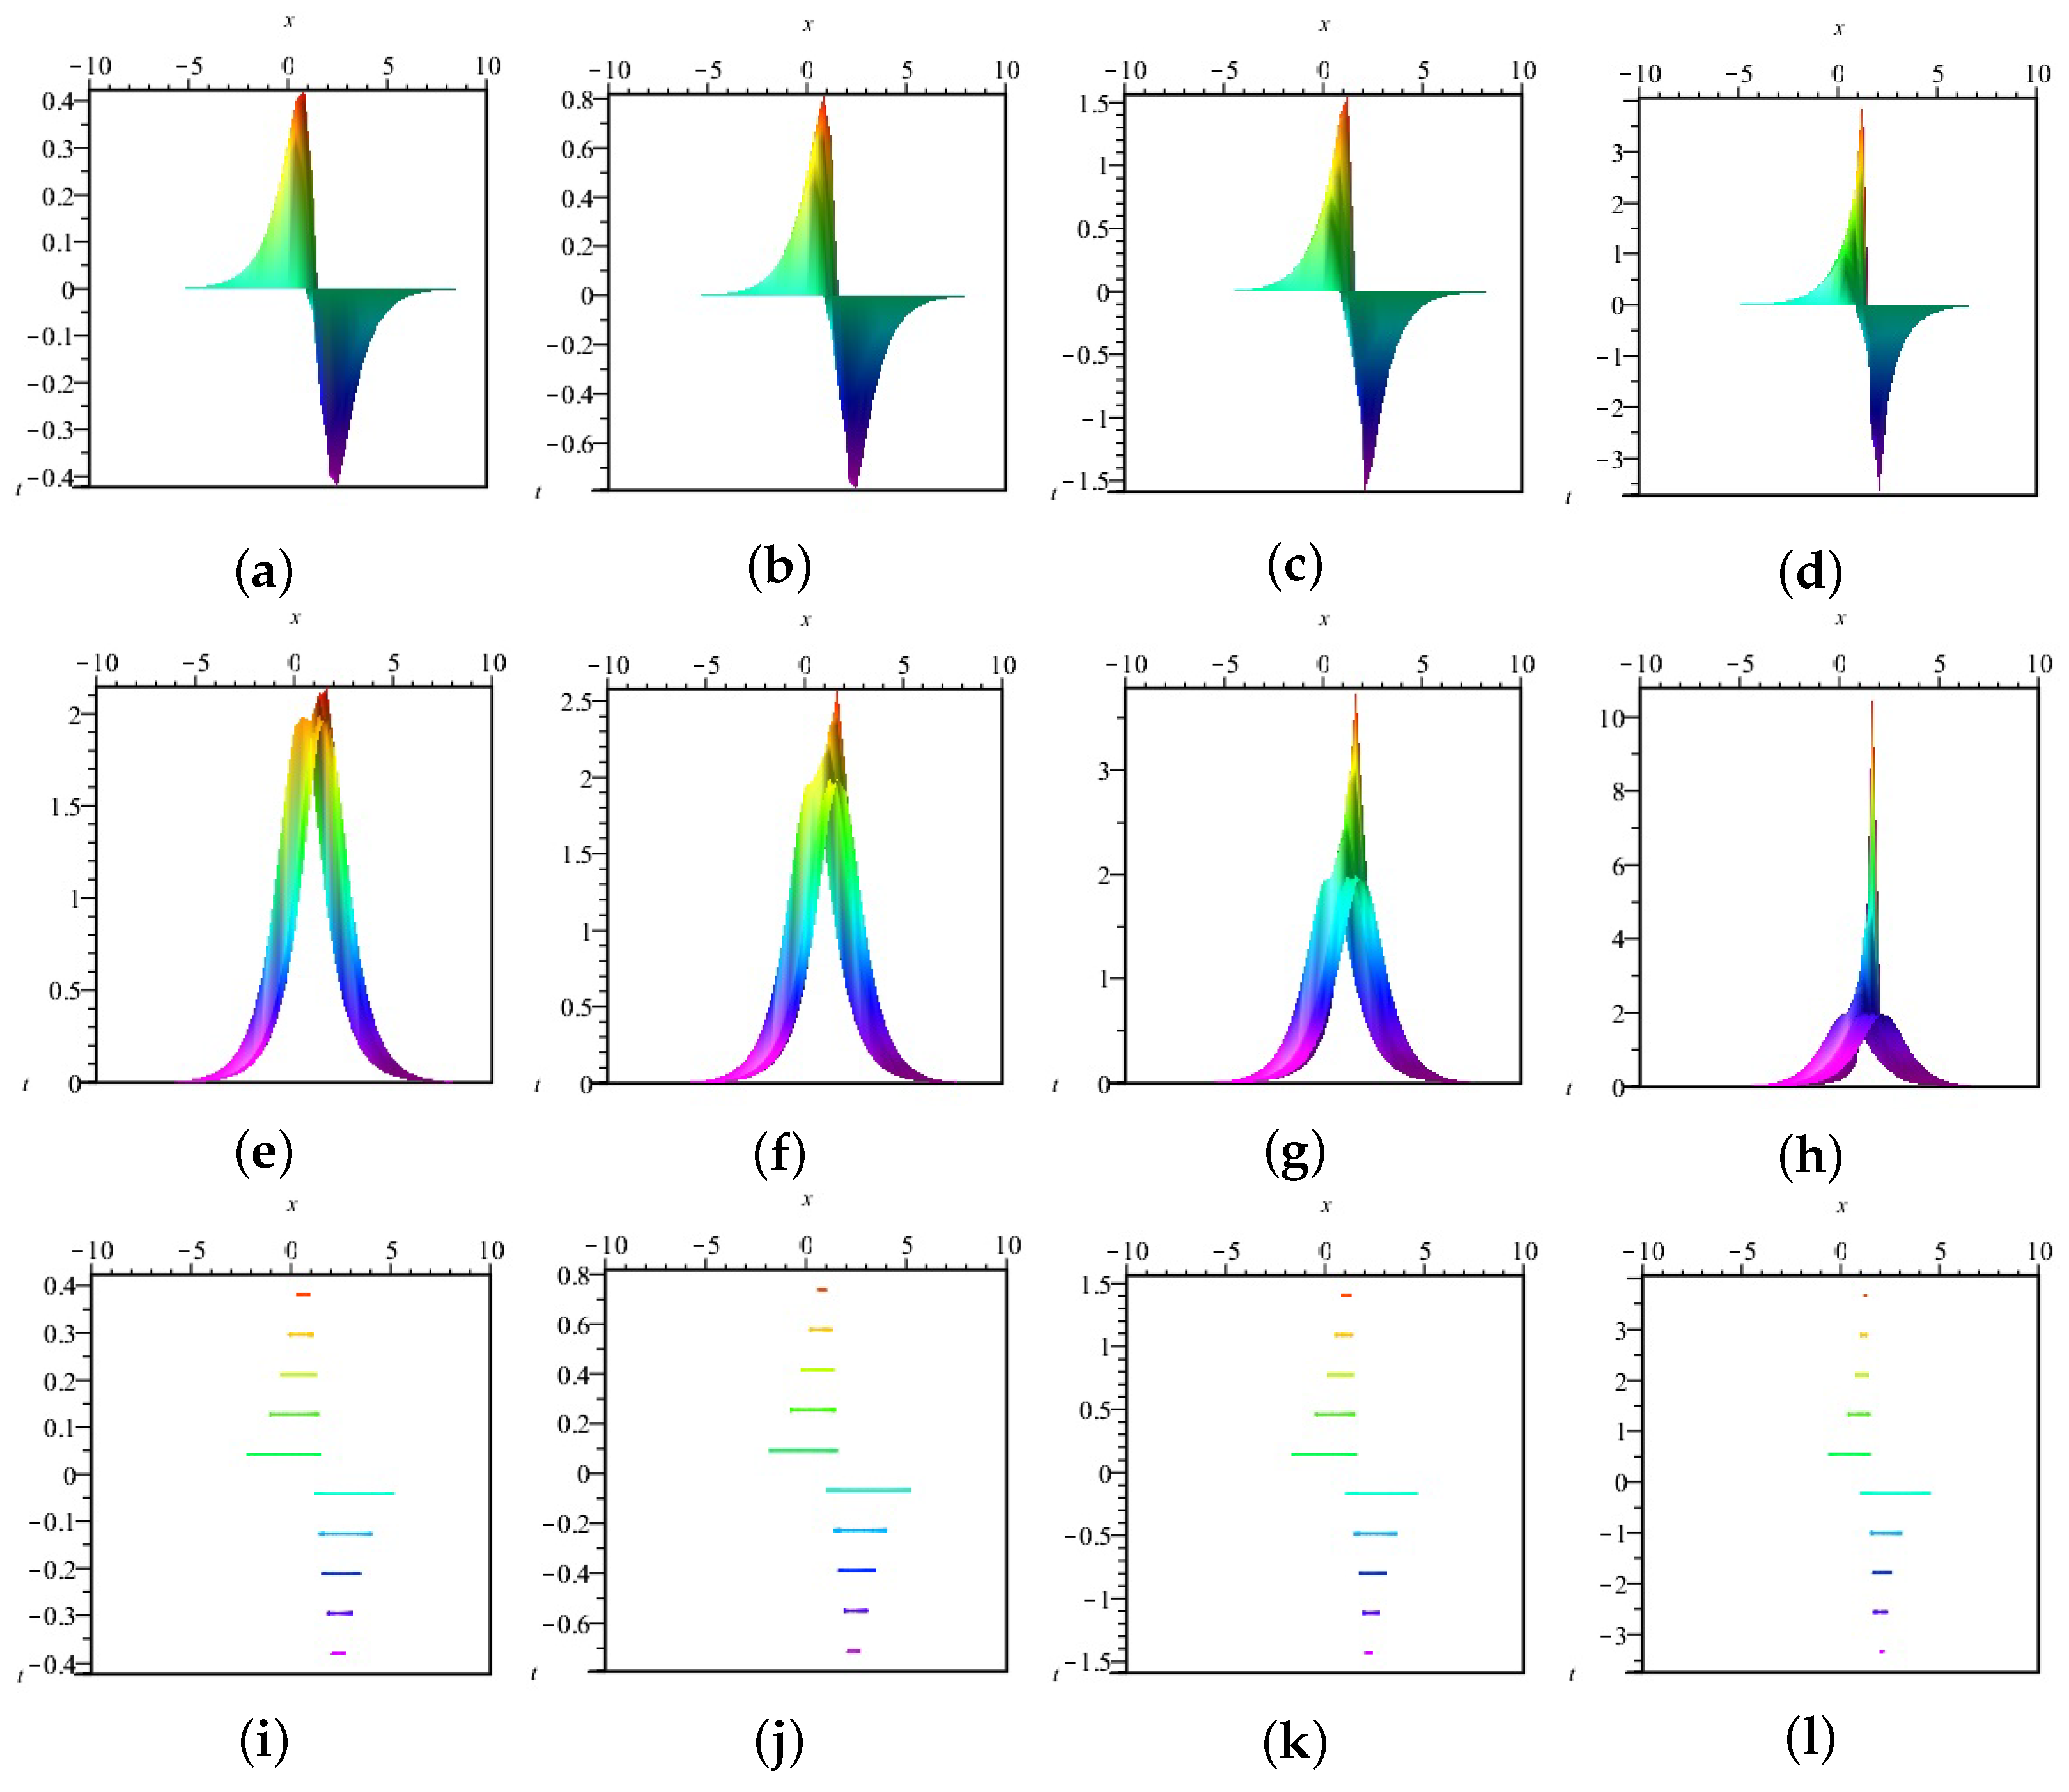
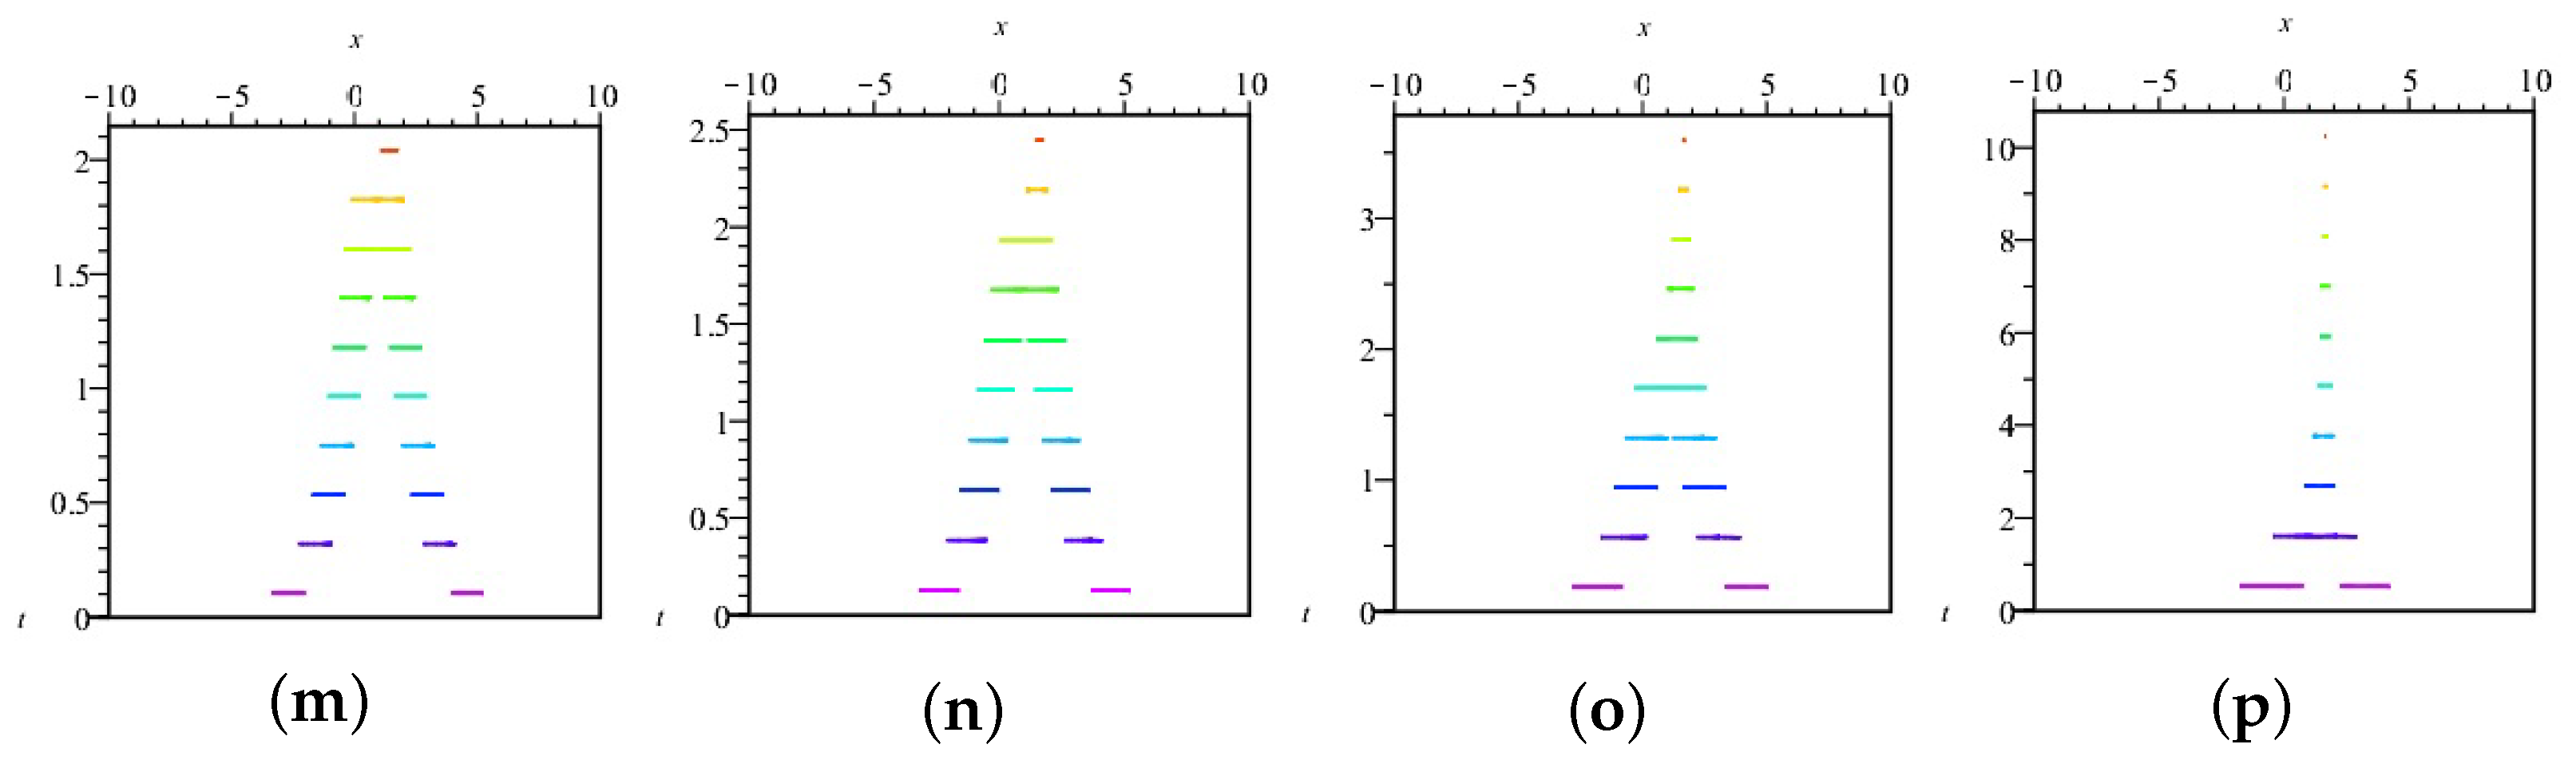
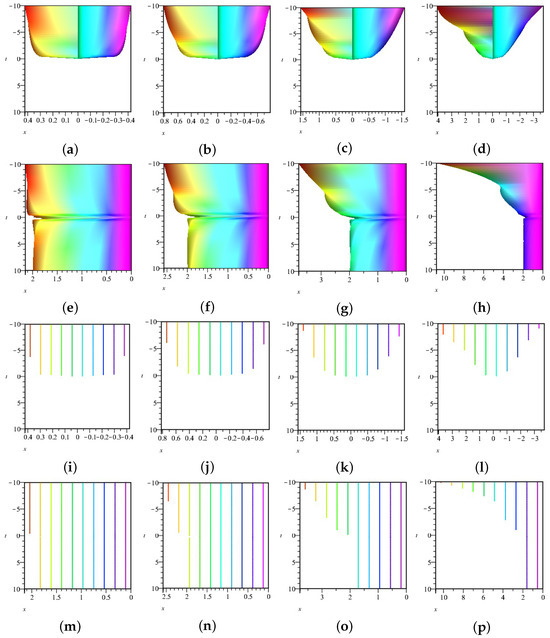
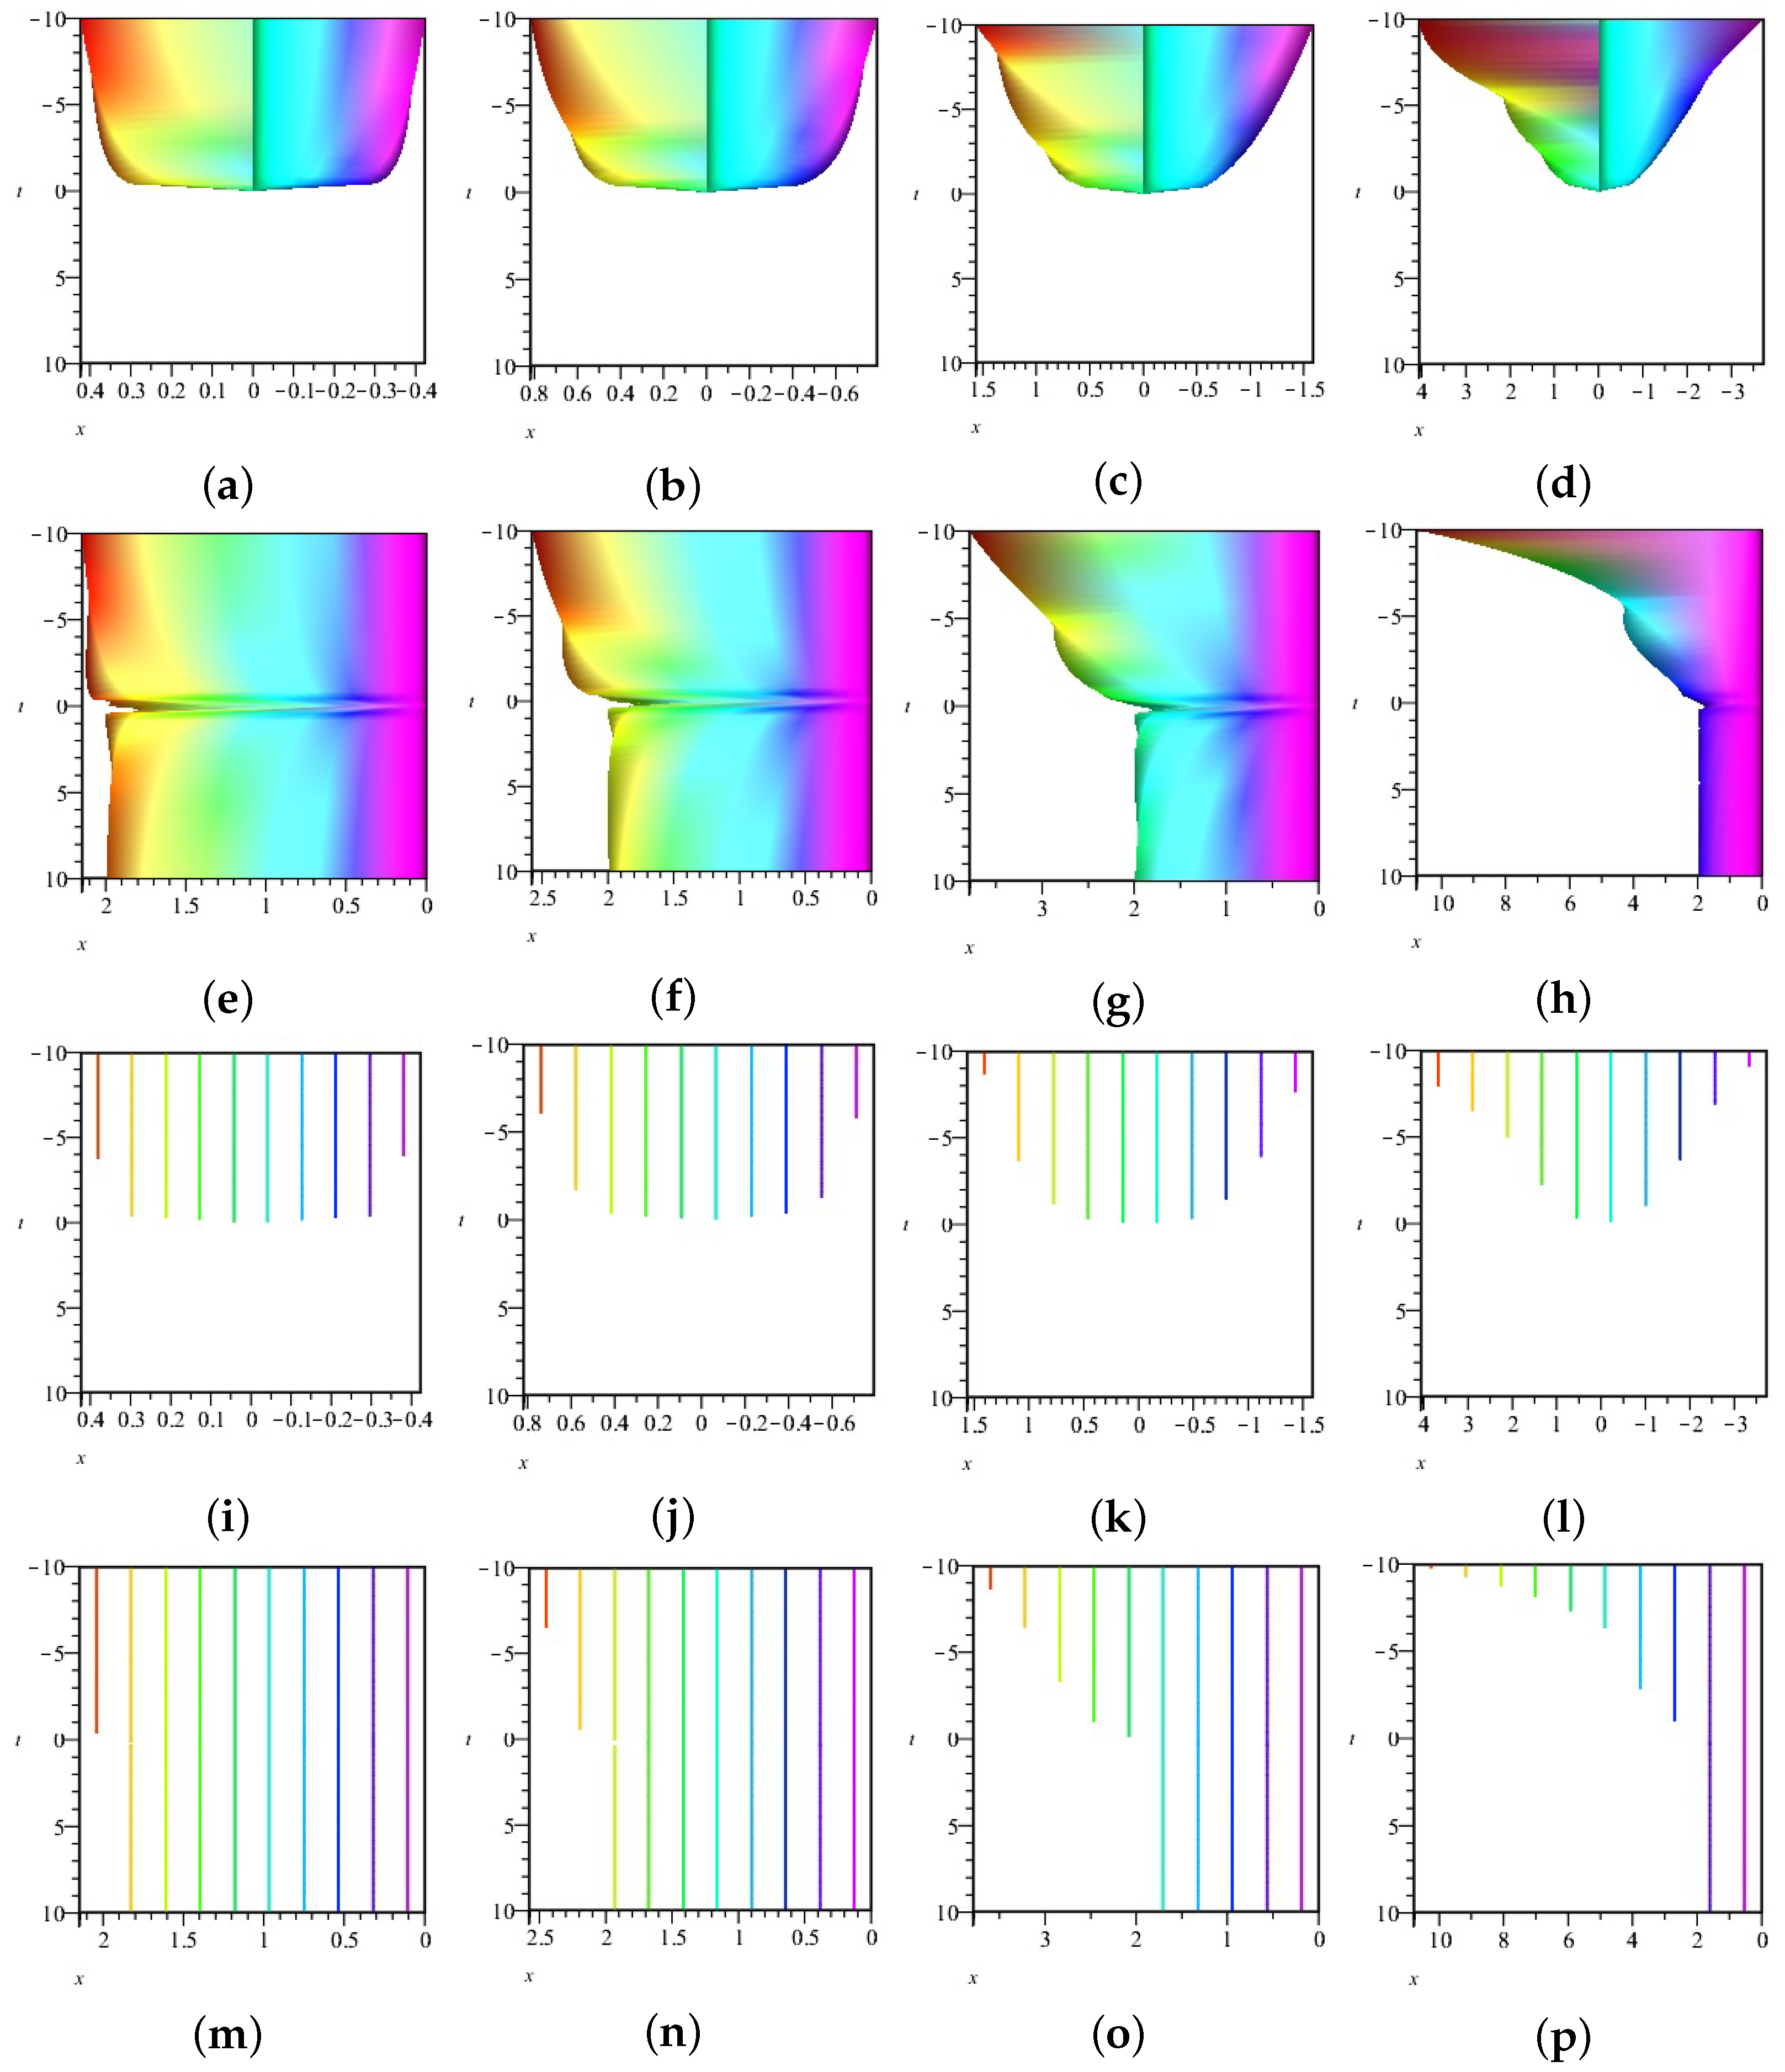
Figure 3, Figure 4, Figure 5, Figure 6, Figure 7 and Figure 8 display The 2-d with the plots of the imaginary and real parts of (43), for diverse values of
Figure 3.
(a–d) The 2D with the diagrams of the real part of (43), in the z-axis orientation, for .
Figure 4.
(a–d) The 2D with the diagrams of the imaginary part of (43), in the z-axis orientation, for .
Figure 5.
(a–d) The contour plots of the real part of (43), in the z-axis orientation, for .
Figure 6.
(a–d) The contour plots of the imaginary part of (43), in the z-axis orientation, for .
Figure 7.
The 2D with the diagrams of the real part of (43), in the x-axis orientation (a–d,i–l) and the y-axis orientation (e–h,m–p), for .
Figure 8.
The 2D with the diagrams of the imaginary part of (43), in the x-axis orientation (a–d,i–l) and the y-axis orientation (e–h,m–p), for .
4. Symmetric Random Finite-Time Stability of (1) for Case 2
4.1. Explicit Formula of Solutions
Making use of [8,10], we propose the proof of the theorem below:
Theorem 2.
(i) For the delayed Mittag–Leffler matrix we have that
i.e., is a solution of
with initial condition for every
(ii) The solution of (1), has the following form
Proof.
(i) For every Thus, (44) holds. For every and Notice that Then, (44) also holds. For every with we have the following items:
- (i.a)
- For and we getNow, applying the fractional-order derivative in the Caputo sense, by (45) and Lemma 2, we get
- (i.b)
- For and we obtain
- (i.c)
- For , with we haveFor through elementary computation, we obtainNow, applying the fractional-order derivative in the Caputo sense by (49) and Lemma 2, we getthus, (44) holds, for every with
(ii) Suppose matrix satisfies (i) of Theorem 2, and every solution of (1) satisfies the initial condition for every Then
where is a constant vector, and is a vector of a continuously differentiable function. Based on being a solution of (1), thus, for arbitrary and (49) is also a solution of (1). Then, we claim and satisfy the initial condition for every
Considering and from (16), we get and with Therefore, and (49) takes the following form
For we have the following two cases:
- (ii.a)
- For every so the delayed Mittag–Leffler matrix is equivalent to
- (ii.b)
- For every so the delayed Mittag–Leffler matrix is equivalent to
Then, for every , we get
Taking the derivative in (50), we have □
4.2. Symmetric Random Stability Results
Definition 7.
Fractional-order system (1) is random finite-time stable w.r.t iff implies that for every and with the initial time of observation and every with
Theorem 3.
(i) Let If
for every then, (1) is random finite-time stable, w.r.t.
(ii) Let κ and be constants, s.t., for every If
for every then, (1) is random finite-time stable, w.r.t.
Proof.
(i) In view of item (ii) of Theorem 2, the solution of fractional system (1) has the form below:
According to Lemma 1, and (51), we get
for every and by noting that
(ii) From integration by parts, (53) has the following form:
by and
Making use of Lemma 1 and (52), we obtain
for every in which we use the relation for and □
5. Representation of Solutions to (1) for Case 3
Making use of [8,10], we present the proof of the theorem below:
Theorem 4.
Every solution of (1), with the initial condition for every has the following form
Proof.
Making use of the variation of constants method, every solution of non-homogeneous system has the form below:
in which is a vector function for every and
Applying the fractional-order derivative in the Caputo sense on both sides of (55), we get the items below:
- (i)
- For every based on (1), we obtainHere, notice thatIn view of Lemma 3 and the definition of the Caputo fractional derivative, we getThus, we have
- (ii)
- For every with based on (1), we getBy the definition of the Caputo fractional derivative, we obtainIn view of Lemmas 3 and 4, we have thatThus,
□
It is straightforward that every solution of (1) for Case 3 has the form in which is a solution of (1) for Case 2, with the initial condition for every and is a solution of (1) for Case 3, with Considering the above descriptions, we will present the formula of solutions to (1) for Case 3, in the theorem below:
Theorem 5.
Every solution of (1) for Case 3 is given by
6. Fuzzy Finite-Time Stability of (1) for Case 4
Definition 8.
The function is a solution of (1) for Case 4, if,
Let us consider the assumptions below:
- The contractive mapping has the contraction property w.r.t the second component with positive Lipschitz constant i.e.,
- for every fixed number
- There is a s.t. for every and
- There is a with and s.t., for every and andLet
Theorem 6.
Let and hold. Then, (1) has a unique solution
Proof.
Consider the operator defined by
The function is well-defined because of We prove is a contraction mapping. Applying Lemma 5, for every and we have that
which infers that
Through one can use contraction mapping principle to complete the proof. □
Definition 9.
Suppose is a solution of (1). Fractional order Equations (1) and (2) is fuzzy finite-time stable w.r.t iff, infers that in which is the initial time, and are positive, with and
Theorem 7.
(i) Assume the assumptions and hold. For the fixed if, for every
then the fractional order system (1) and (2) is fuzzy finite-time stable w.r.t
(ii) Assume the assumptions and hold and For the fixed if,
then the fractional order system (1) and (2) is fuzzy finite-time stable w.r.t
(iii) Assume the assumptions and hold and For the fixed if,
then the fractional order system (1) and (2) is fuzzy finite-time stable w.r.t
Proof.
(i) Through the assumptions and and Theorem 6, we have that (1) has a unique solution Making use of Lemmas 1, 5 and 6 and (56), we get
□
Example
Consider the fractional-order system below
where , and
The solution of fractional system (61) and (62) has the following form:
Now, we have that
and
where and
Making use of the above inequalities, we get
Here, we let
Making use of the arithmetric mean aggregation map and the maximum aggregation map we calculate the numerical results of finite-time stability for fractional-order system (61) and (62) (see Table 1). In view of the required conditions in cases (i), (ii), (iii) of Theorem 7, we obtain the relative optimal thresholds and
Table 1.
Stability results of Example 1.
7. Conclusions
The main target of this paper is to provide a new interpretation of Ulam type stability with the application of classical, well-known special functions and aggregation maps. This new notion of stability not only covers the previous notions but also considers the optimization of the problem. This stability allows us to get the best approximation error estimates for different fractional-order systems. In addition, we will be able to obtain maximal stability with minimal error which leads to calculate the optimal solution.
Author Contributions
D.O., methodology, writing—original draft preparation. S.R.A., writing—original draft preparation. R.S., supervision and project administration. C.L., editing and methodology. All authors read and approved the final manuscript.
Funding
This research received no external funding.
Data Availability Statement
Here by we confirm that there is no available and applicable data for this research. The research process is independent from any dataset.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Arif, M.; Di Persio, L.; Kumam, P.; Watthayu, W.; Akgül, A. Heat transfer analysis of fractional model of couple stress Casson tri-hybrid nanofluid using dissimilar shape nanoparticles in blood with biomedical applications. Sci. Rep. 2023, 13, 4596. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Turkyilmazoglu, M.; Altanji, M. Fractional models of falling object with linear and quadratic frictional forces considering Caputo derivative. Chaos, Solitons Fractals 2023, 166, 112980. [Google Scholar] [CrossRef] [Scilit]
- Khan, N.; Ali, F.; Ahmad, Z.; Murtaza, S.; Ganie, A.H.; Khan, I.; Eldin, S.M. A time fractional model of a Maxwell nanofluid through a channel flow with applications in grease. Sci. Rep. 2023, 13, 4428. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Baleanu, D.; Arshad, S.; Jajarmi, A.; Shokat, W.; Ghassabzade, F.A.; Wali, M. Dynamical behaviours and stability analysis of a generalized fractional model with a real case study. J. Adv. Res. 2023, 48, 157–173. [Google Scholar] [CrossRef] [Scilit]
- Tarasov, V.E. (Ed.) Handbook of Fractional Calculus with Applications: Applications in Physics, Part B; de Gruyter: Berlin, Germany, 2019. [Google Scholar]
- Diblík, J.; Khusainov, D.Y. Representation of solutions of discrete delayed system x(k+1)=Ax(k)+Bx(k-m)+f(k) with commutative matrices. J. Math. Anal. Appl. 2006, 318, 63–76. [Google Scholar] [CrossRef] [Scilit]
- Khusainov, D.Y.; Shuklin, G.V. Linear autonomous time-delay system with permutation matrices solving. Stud. Univ. Zilina 2003, 17, 101–108. [Google Scholar]
- Li, M.; Wang, J. Exploring delayed Mittag-Leffler type matrix functions to study finite time stability of fractional delay differential equations. Appl. Math. Comput. 2018, 324, 254–265. [Google Scholar] [CrossRef] [Scilit]
- Hei, X.; Wu, R. Finite-time stability of impulsive fractional-order systems with time-delay. Appl. Math. Model. 2016, 40, 4285–4290. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Wang, J. Finite time stability of fractional delay differential equations. Appl. Math. Lett. 2017, 64, 170–176. [Google Scholar] [CrossRef] [Scilit]
- Pospisil, M. Representation and stability of solutions of systems of functional differential equations with multiple delays. Electron. J. Qual. Theory Differ. Equ. 2012, 2012, 1–30. [Google Scholar] [CrossRef] [Scilit]
- Senasukh, J.; Saejung, S. A Note on the Stability of Some Functional Equations on Certain Groupoids. Constr. Math. Anal. 2020, 3, 96–103. [Google Scholar] [CrossRef] [Scilit]
- Park, C.; Yun, S.; Lee, J.R.; Shin, D.Y. Set-Valued Additive Functional fixeds. Constr. Math. Anal. 2019, 2, 89–97. [Google Scholar]
- Zhao, J.; Yuan, Y.; Sun, Z.Y.; Xie, X. Applications to the dynamics of the suspension system of fast finite time stability in probability of p-norm stochastic nonlinear systems. Appl. Math. Comput. 2023, 457, 128221. [Google Scholar] [CrossRef] [Scilit]
- Panda, S.K.; Vijayakumar, V. Results on finite time stability of various fractional order systems. Chaos, Solitons Fractals 2023, 174, 113906. [Google Scholar] [CrossRef] [Scilit]
- Yang, Z.; Zhang, J.; Zhang, Z.; Mei, J. An improved criterion on finite-time stability for fractional-order fuzzy cellular neural networks involving leakage and discrete delays. Math. Comput. Simul. 2023, 203, 910–925. [Google Scholar] [CrossRef] [Scilit]
- Aderyani, S.R.; Saadati, R.; Abdeljawad, T.; Mlaiki, N. Multi-stability of non homogenous vector-valued fractional differential equations in matrix-valued Menger spaces. Alex. Eng. J. 2022, 61, 10913–10923. [Google Scholar] [CrossRef] [Scilit]
- Aderyani, S.R.; Saadati, R. Stability and controllability results by n–ary aggregation functions in matrix valued fuzzy n-normed spaces. Inf. Sci. 2023, 643, 119265. [Google Scholar] [CrossRef] [Scilit]
- Olutimo, A.L.; Bilesanmi, A.; Omoko, I.D. Stability and boundedness analysis for a system of two nonlinear delay differential equations. J. Nonlinear Sci. Appl. 2023, 16, 90–98. [Google Scholar] [CrossRef] [Scilit]
- Agarwal, R.; Chandola, A.; Mishra Pandey, R.; Sooppy Nisar, K. m-Parameter Mittag–Leffler function, its various properties, and relation with fractional calculus operators. Math. Methods Appl. Sci. 2021, 44, 5365–5384. [Google Scholar] [CrossRef] [Scilit]
- Abubakar, U.M. Some results on generalized Euler-type integrals related to the four parameters Mittag-Leffler function. J. New Results Sci. 2021, 10, 1–10. [Google Scholar] [CrossRef] [Scilit]
- Özarslan, M.A.; Fernandez, A. On a five-parameter Mittag-Leffler function and the corresponding bivariate fractional operators. Fractal Fract. 2021, 5, 45. [Google Scholar] [CrossRef] [Scilit]
- Youssef, M.I. Generalized fractional delay functional equations with Riemann-Stieltjes and infinite point nonlocal conditions. J. Math. Comput. Sci. 2022, 24, 33–48. [Google Scholar] [CrossRef] [Scilit]
- Long, L.D. Cauchy problem for inhomogeneous fractional nonclassical diffusion equation on the sphere. J. Math. Comput. Sci. 2022, 25, 303–311. [Google Scholar] [CrossRef] [Scilit]
- Asjad, M.I.; Ullah, N.; Rehman, H.; Baleanu, D. Optical solitons for conformable space-time fractional nonlinear model. J. Math. Comput. Sci. 2022, 27, 28–41. [Google Scholar] [CrossRef] [Scilit]
- Wusu, A.S.; Olabanjo, O.A.; Akanbi, M.A. A model for analysing the dynamics of the second wave of corona virus (COVID-19) in Nigeria. J. Math. Comput. Sci. 2022, 26, 16–21. [Google Scholar] [CrossRef] [Scilit]
- AlAhmad, R.; AlAhmad, Q.; Abdelhadi, A. Solution of fractional autonomous ordinary differential equations. J. Math. Comput. Sci. 2022, 27, 59–64. [Google Scholar] [CrossRef] [Scilit]
- Long, P.; Murugusundaramoorthy, G.; Tang, H.; Wang, W. Subclasses of analytic and bi-univalent functions involving a generalized Mittag-Leffler function based on quasi-subordination. J. Math. Comput. Sci. 2022, 26, 379–394. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.J. Theory and Applications of Special Functions for Scientists and Engineers; Springer: Singapore, 2021. [Google Scholar]
- Pan, R.; Fan, Z. Analyses of solutions of Riemann Liouville fractional oscillatory differential equations with pure delay. In Mathematical Methods in the Applied Sciences; 2023; Available online: https://www.authorea.com/doi/full/10.22541/au.166375802.26875853/v1 (accessed on 6 September 2023).

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2023 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).