


Abstract
In response to issues such as the strong output power fluctuations of photovoltaic units caused by external environmental factors like solar irradiance, and the susceptibility of traditional control methods to grid disconnection incidents under significant system disturbances, a control strategy based on cascaded linear-nonlinear Extended State Observer (ESO) Active Disturbance Rejection Control (ADRC) is proposed for photovoltaic-storage hybrid systems. A model of the photovoltaic-storage hybrid system is constructed to achieve high- and low-frequency power distribution among energy storage units. The cascaded linear-nonlinear ESO-based ADRC is employed to estimate and compensate for system disturbances in real-time. Simulation results verify the effectiveness of the proposed control strategy, demonstrating a reduction in frequency deviation by 0.08 Hz under normal frequency dips. More critically, during severe AC bus voltage sags, the proposed strategy prevents the system frequency from falling below 49.0 Hz, thereby avoiding the under-frequency load shedding (UFLS) that occurs with conventional PI control. Additionally, the DC bus voltage fluctuation is limited to within 8 V under grid disturbances, and unlike the severe oscillations exhibited by PI control during system recovery, the proposed cascade strategy ensures an immediate and smooth transient response.
1. Introduction
To accelerate the transition toward green and low-carbon energy, China’s power system is progressively evolving toward high penetration of renewable energy sources and a power-electronics-dominated structure [1,2]. As of 2023, the cumulative installed capacity of photovoltaic (PV) units in China reached about 6.1 GW, accounting for 21% of the nation’s total installed power generation capacity [3]. Due to the influence of uncertain factors such as light intensity and irradiation duration, the output power of PV units exhibits volatility and randomness [4]. Moreover, PV units are integrated into the distribution grid via power electronic converters, which may lead to decoupling from the system frequency, preventing them from actively providing active power support for frequency stability. This issue aligns with the growing concerns reflected in international grid codes, such as IEEE 1547 [5] and ENTSO-E requirements, which increasingly mandate enhanced dynamic support from inverter-based resources. Consequently, the large-scale grid integration of PV units poses significant challenges to the stable operation of the power system.
Numerous studies have been conducted on the participation of PV units in system frequency regulation. Based on a two-stage PV topology. Reference [6] proposed a nonlinear adaptive disturbance rejection control strategy based on VSG for photovoltaic-storage grid-connected inverters, enhancing the system dynamic response under varying conditions. Reference [7] presented an active power control strategy using power reserve control for single-stage PV systems, enabling the PV array voltage to respond directly to grid voltage and providing inherent inertial response. However, the fault tolerance of PV units is lower than that of traditional synchronous generators [8], making them prone to grid disconnection during fault disturbances. In contrast, energy storage systems can achieve bidirectional power regulation with the distribution network through converters [9], effectively smoothing PV output fluctuations and serving as a necessary complement to intermittent renewable energy generation equipment. To address the distinct timescales of PV power fluctuations, a Hybrid Energy Storage System (HESS) combining batteries and supercapacitors is often employed, where the high-energy-density battery manages long-term power shifting and the high-power-density supercapacitor absorbs rapid transients. Reference [10] established an energy storage system model based on a Thevenin equivalent circuit. To address output power fluctuations from intermittent energy sources connected to the grid, reference [11] employed an outer-loop power and inner-loop current control strategy, effectively suppressing power fluctuations in wind-PV systems. Based on a standalone PV-storage system, reference [12] utilized voltage stabilization control to maintain stable output; however, the model construction employed a traditional battery structure, which cannot respond rapidly to fluctuations in PV output power. Beyond the system-level configuration, the modeling fidelity of individual HESS components also warrants attention. For supercapacitors, equivalent circuit models incorporating parasitic elements (such as series resistance and leakage inductance) have been shown to be critical for accurate dynamic analysis in DC–DC conversion applications [13]. For battery storage, the temporal resolution of simulation data significantly affects the accuracy of response prediction and component lifetime estimation; studies have demonstrated that time steps coarser than 30 min can lead to noticeable deviations in key performance indicators [14].
In power systems, frequency stability is a crucial indicator for evaluating system performance. The Virtual Synchronous Generator (VSG) control technology emulates the damping and rotational inertia of synchronous generators through inverters, adjusting the output power based on frequency deviations to provide instantaneous power support. Reference [15] presented a VSG-based grid-connected photovoltaic generation system with hybrid energy storage, demonstrating improved virtual inertia and frequency support capability. Reference [16] applied a sliding mode control strategy to the active power control loop of VSGs, significantly suppressing drastic frequency variations. However, the effectiveness of VSG technology in highly volatile PV environments depends critically on the controller’s ability to estimate and reject disturbances in real time, which motivates the integration of Extended State Observer (ESO) techniques. The Extended State Observer (ESO) is an observer used to estimate system states and total disturbances, widely applied in fields such as power electronic converters and grid-forming inverter control. Reference [17] applied an ESO-based ADRC strategy to a DC microgrid with wave energy conversion, achieving voltage stabilization and improved energy dispatch under stochastic power fluctuations. Reference [18] proposed an LADRC-based control method for grid-forming inverters, demonstrating enhanced stability and phase margin under strong grid conditions. Reference [19] introduced a nonlinear robust excitation control method based on ESO and backstepping, which compensates for uncertainties in the model using ESO and designs control laws via backstepping, enhancing the stability and parameter robustness of the power system. ESO serves as the core component of Active Disturbance Rejection Control (ADRC) technology. ADRC, with its unique internal mechanism design, can autonomously resist and compensate for the effects of external disturbances and internal parameter variations on system performance. Recent studies have further demonstrated its effectiveness in grid-connected inverter applications: a two-stage ESO-cascaded ADRC topology was proposed for DC-link voltage control in LCL-filtered photovoltaic inverters, achieving improved disturbance rejection [20]. Reference [21] confirmed the practical viability of ADRC through extensive experimental validation in power electronic systems. Reference [22] proposed an LADRC-based strategy to suppress sub/super-synchronous oscillations in grid-forming inverters under strong grid conditions, demonstrating superior stability through impedance modeling and Nyquist analysis. Reference [23] introduced LADRC combined with model information (LADRC-MI) for grid-forming converters, where VSG-based control improves system inertia and the model information incorporated into the LESO coefficient matrix enhances disturbance immunity. However, its steady-state tracking accuracy and disturbance rejection capability under small disturbances are insufficient. Reference [24] proposed a switching control strategy between LADRC and Nonlinear Active Disturbance Rejection Control (NLADRC), but this approach is prone to inducing system oscillations during the switching process.
Building upon the aforementioned research, this paper proposes a control strategy for photovoltaic-storage hybrid systems based on a cascaded linear-nonlinear Extended State Observer (ESO). First, a photovoltaic-storage hybrid system incorporating a hybrid energy storage power station is designed. Second, a Linear-Nonlinear Cascaded Active Disturbance Rejection Control (LNCADRC) strategy is proposed. Different from the improved LADRC or NLADRC schemes that enhance a single observer stage [22,23], the switching-based hybrid control approaches [24,25], and the cascaded ADRC developed for motor drives [26], this work introduces a cascaded ESO structure supecifically tailored for DC bus voltage regulation in photovoltaic-storage hybrid systems, wherein the front-stage Linear ADRC (LADRC) ensures stable disturbance rejection under large transients, while the rear-stage Nonlinear ADRC (NLADRC) refines the residual error to enhance steady-state accuracy without incurring switching-induced oscillations. Finally, simulation experiments are conducted in the MATLAB/Simulink (version R2025b) environment to verify the effectiveness of the proposed control strategy.
2. Photovoltaic-Storage Hybrid System
2.1. Topology of the Hybrid PV-Storage Power Generation System
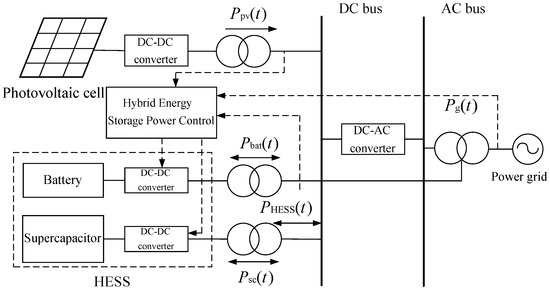
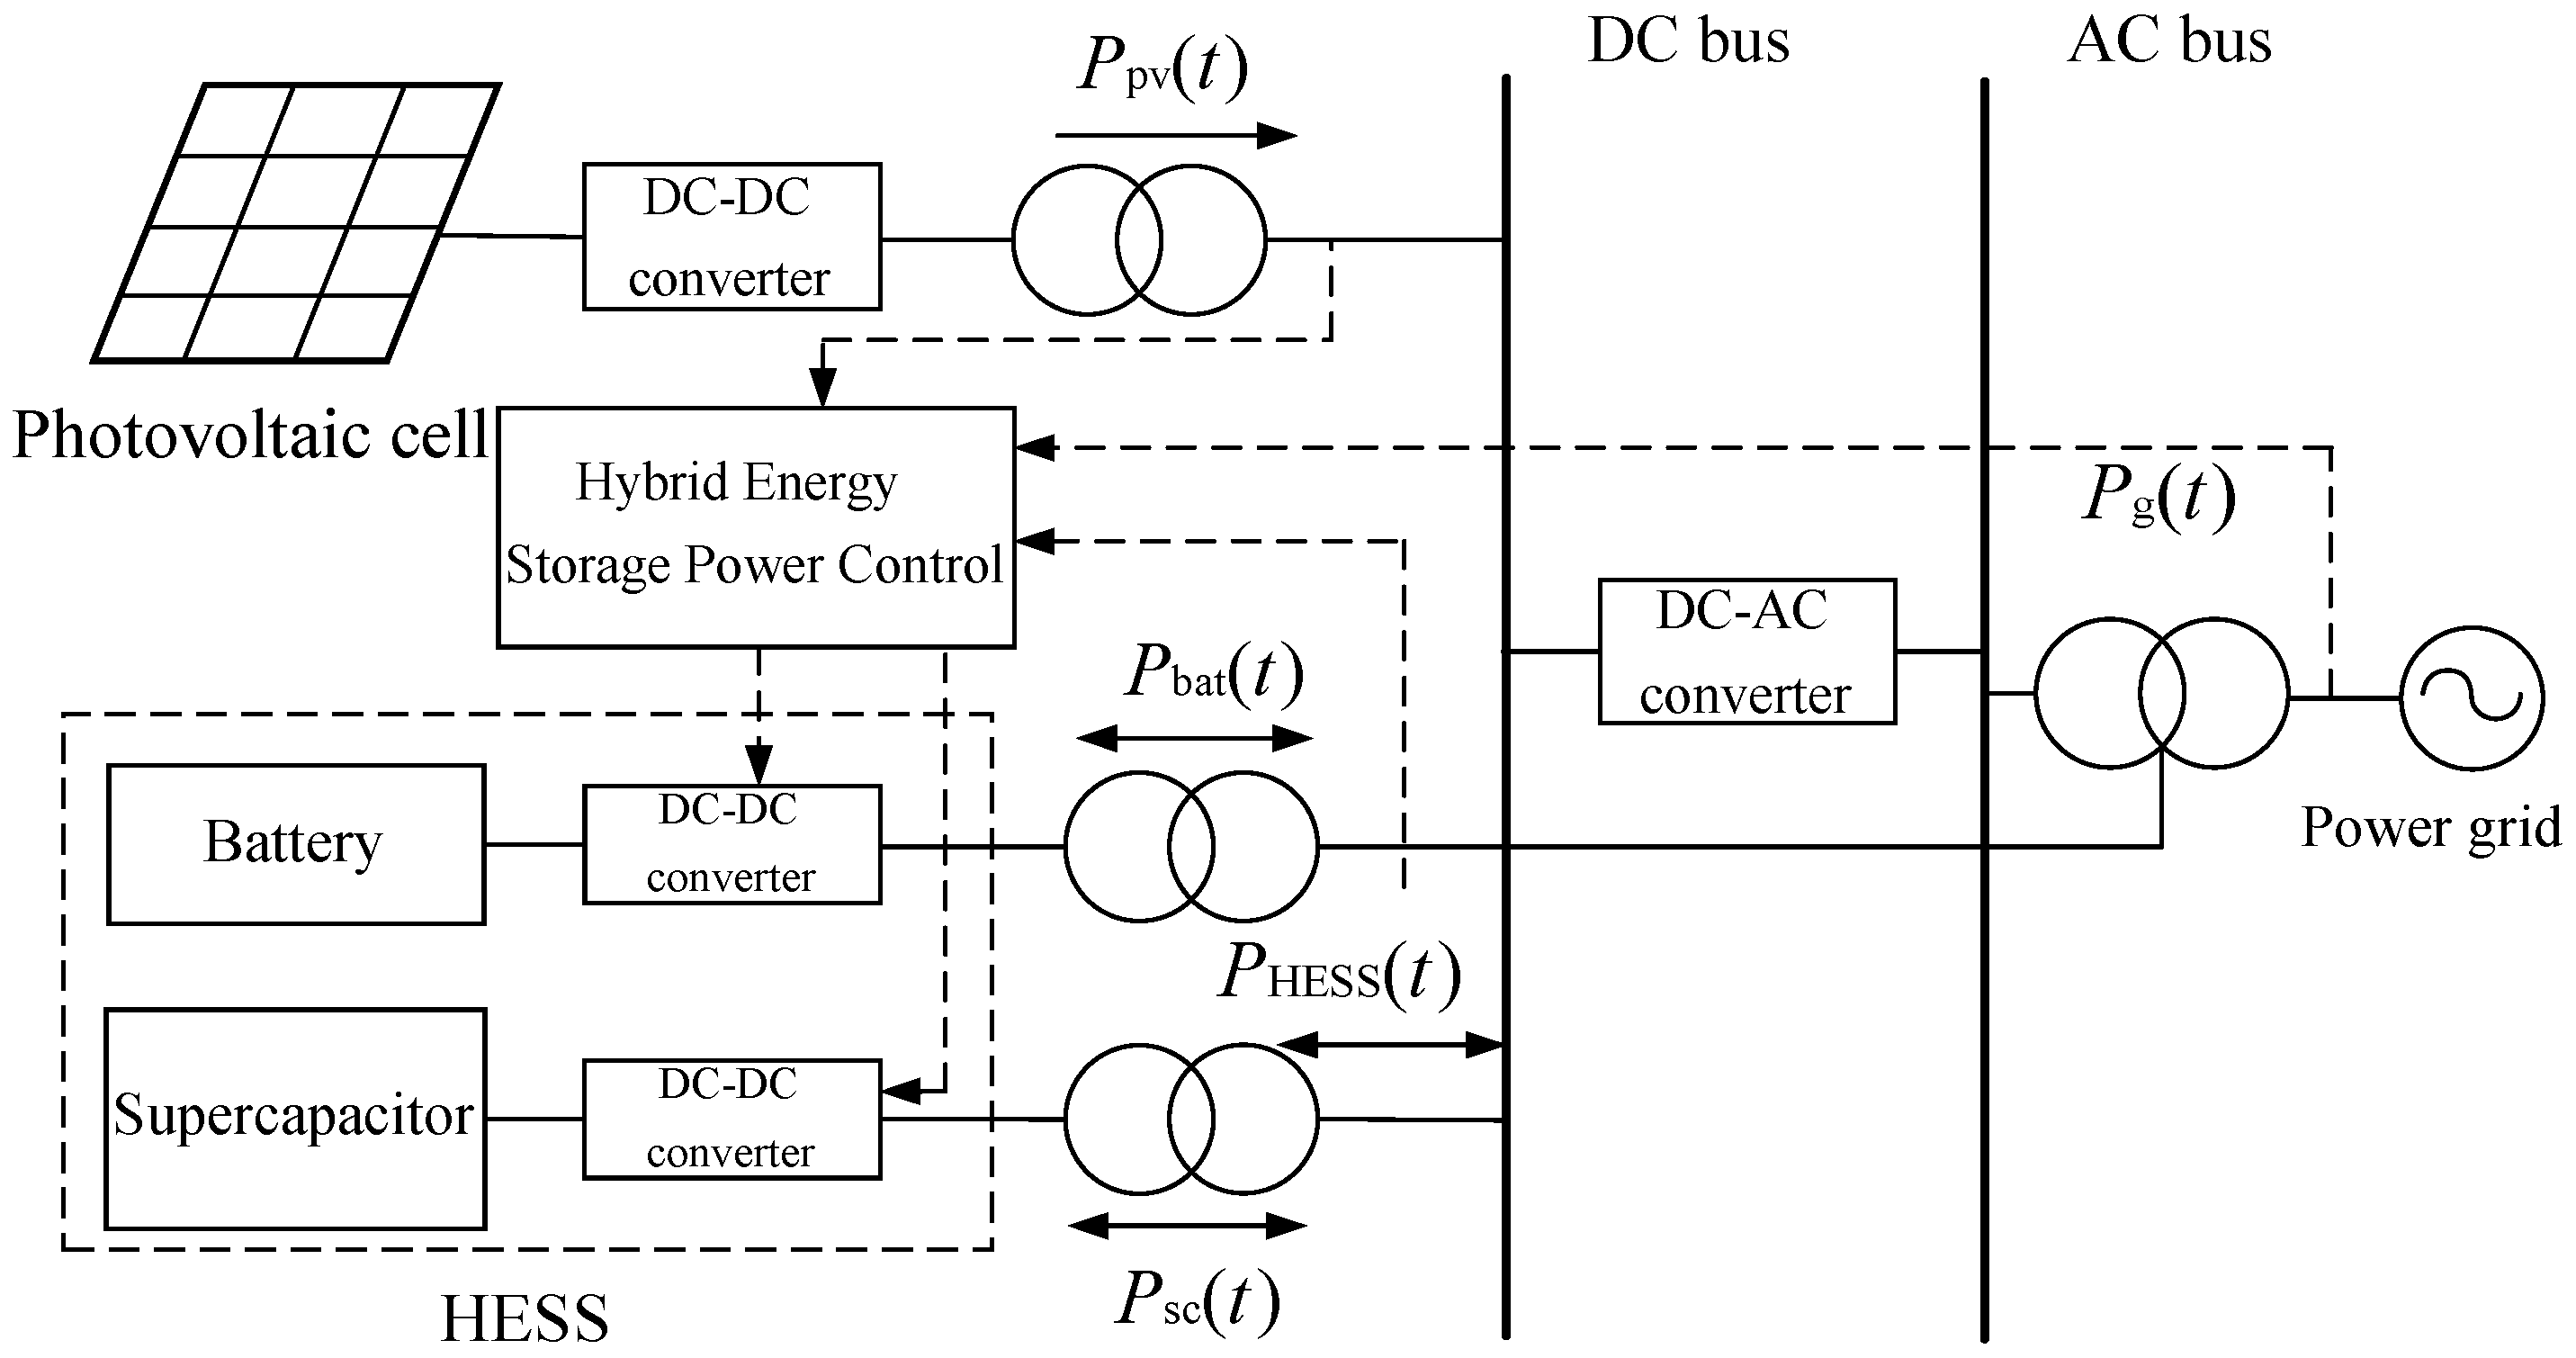
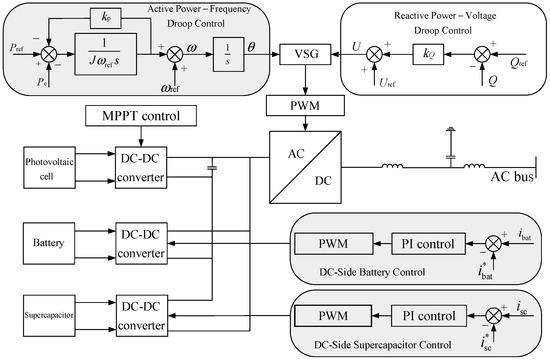
The structure of the photovoltaic-storage hybrid system designed in this paper is shown in Figure 1. The system consists of a photovoltaic cell, HESS, DC-DC converter, DC-AC converter, and power grid. The photovoltaic cells operate under maximum power point tracking (MPPT) mode, while the HESS employs VSG control technology to exchange energy with the system, thereby effectively suppressing fluctuations in the photovoltaic output power.
Figure 1.
Structure diagram of photovoltaic-energy storage system.
In Figure 1, is the grid-connected power of the PV-storage system; is the output power of the PV plant; is the charging/discharging power of the HESS; and are the charging/discharging power of the battery and the supercapacitor, respectively.
According to the power relationship shown in Figure 1, the following can be obtained:
From Equation (1), it can be seen that the reference power of the hybrid energy storage system is the difference between the grid-connected power of the PV-storage system and the original PV output power. When > 0, the HESS is in the discharging state, supplying power; otherwise, it is in the charging state, absorbing power.
Batteries possess high energy density and reliability, but they lack sufficient high-frequency power response capability. Supercapacitors, on the other hand, have significantly higher power density than batteries and can rapidly compensate for high-frequency power fluctuations. The HESS uses the battery to smooth low-frequency fluctuation components and the supercapacitor to smooth high-frequency fluctuation components. Therefore, it combines both types of energy storage components, achieving stable power compensation while quickly responding to power fluctuations, thereby enhancing the overall operational efficiency and stability of the system.
2.2. Converter Topology
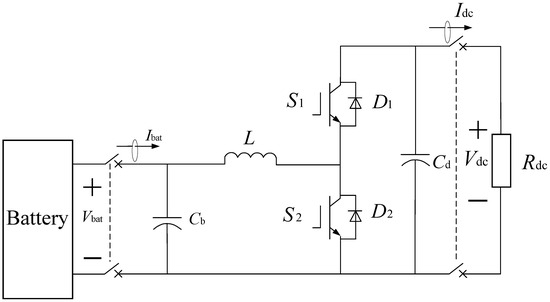
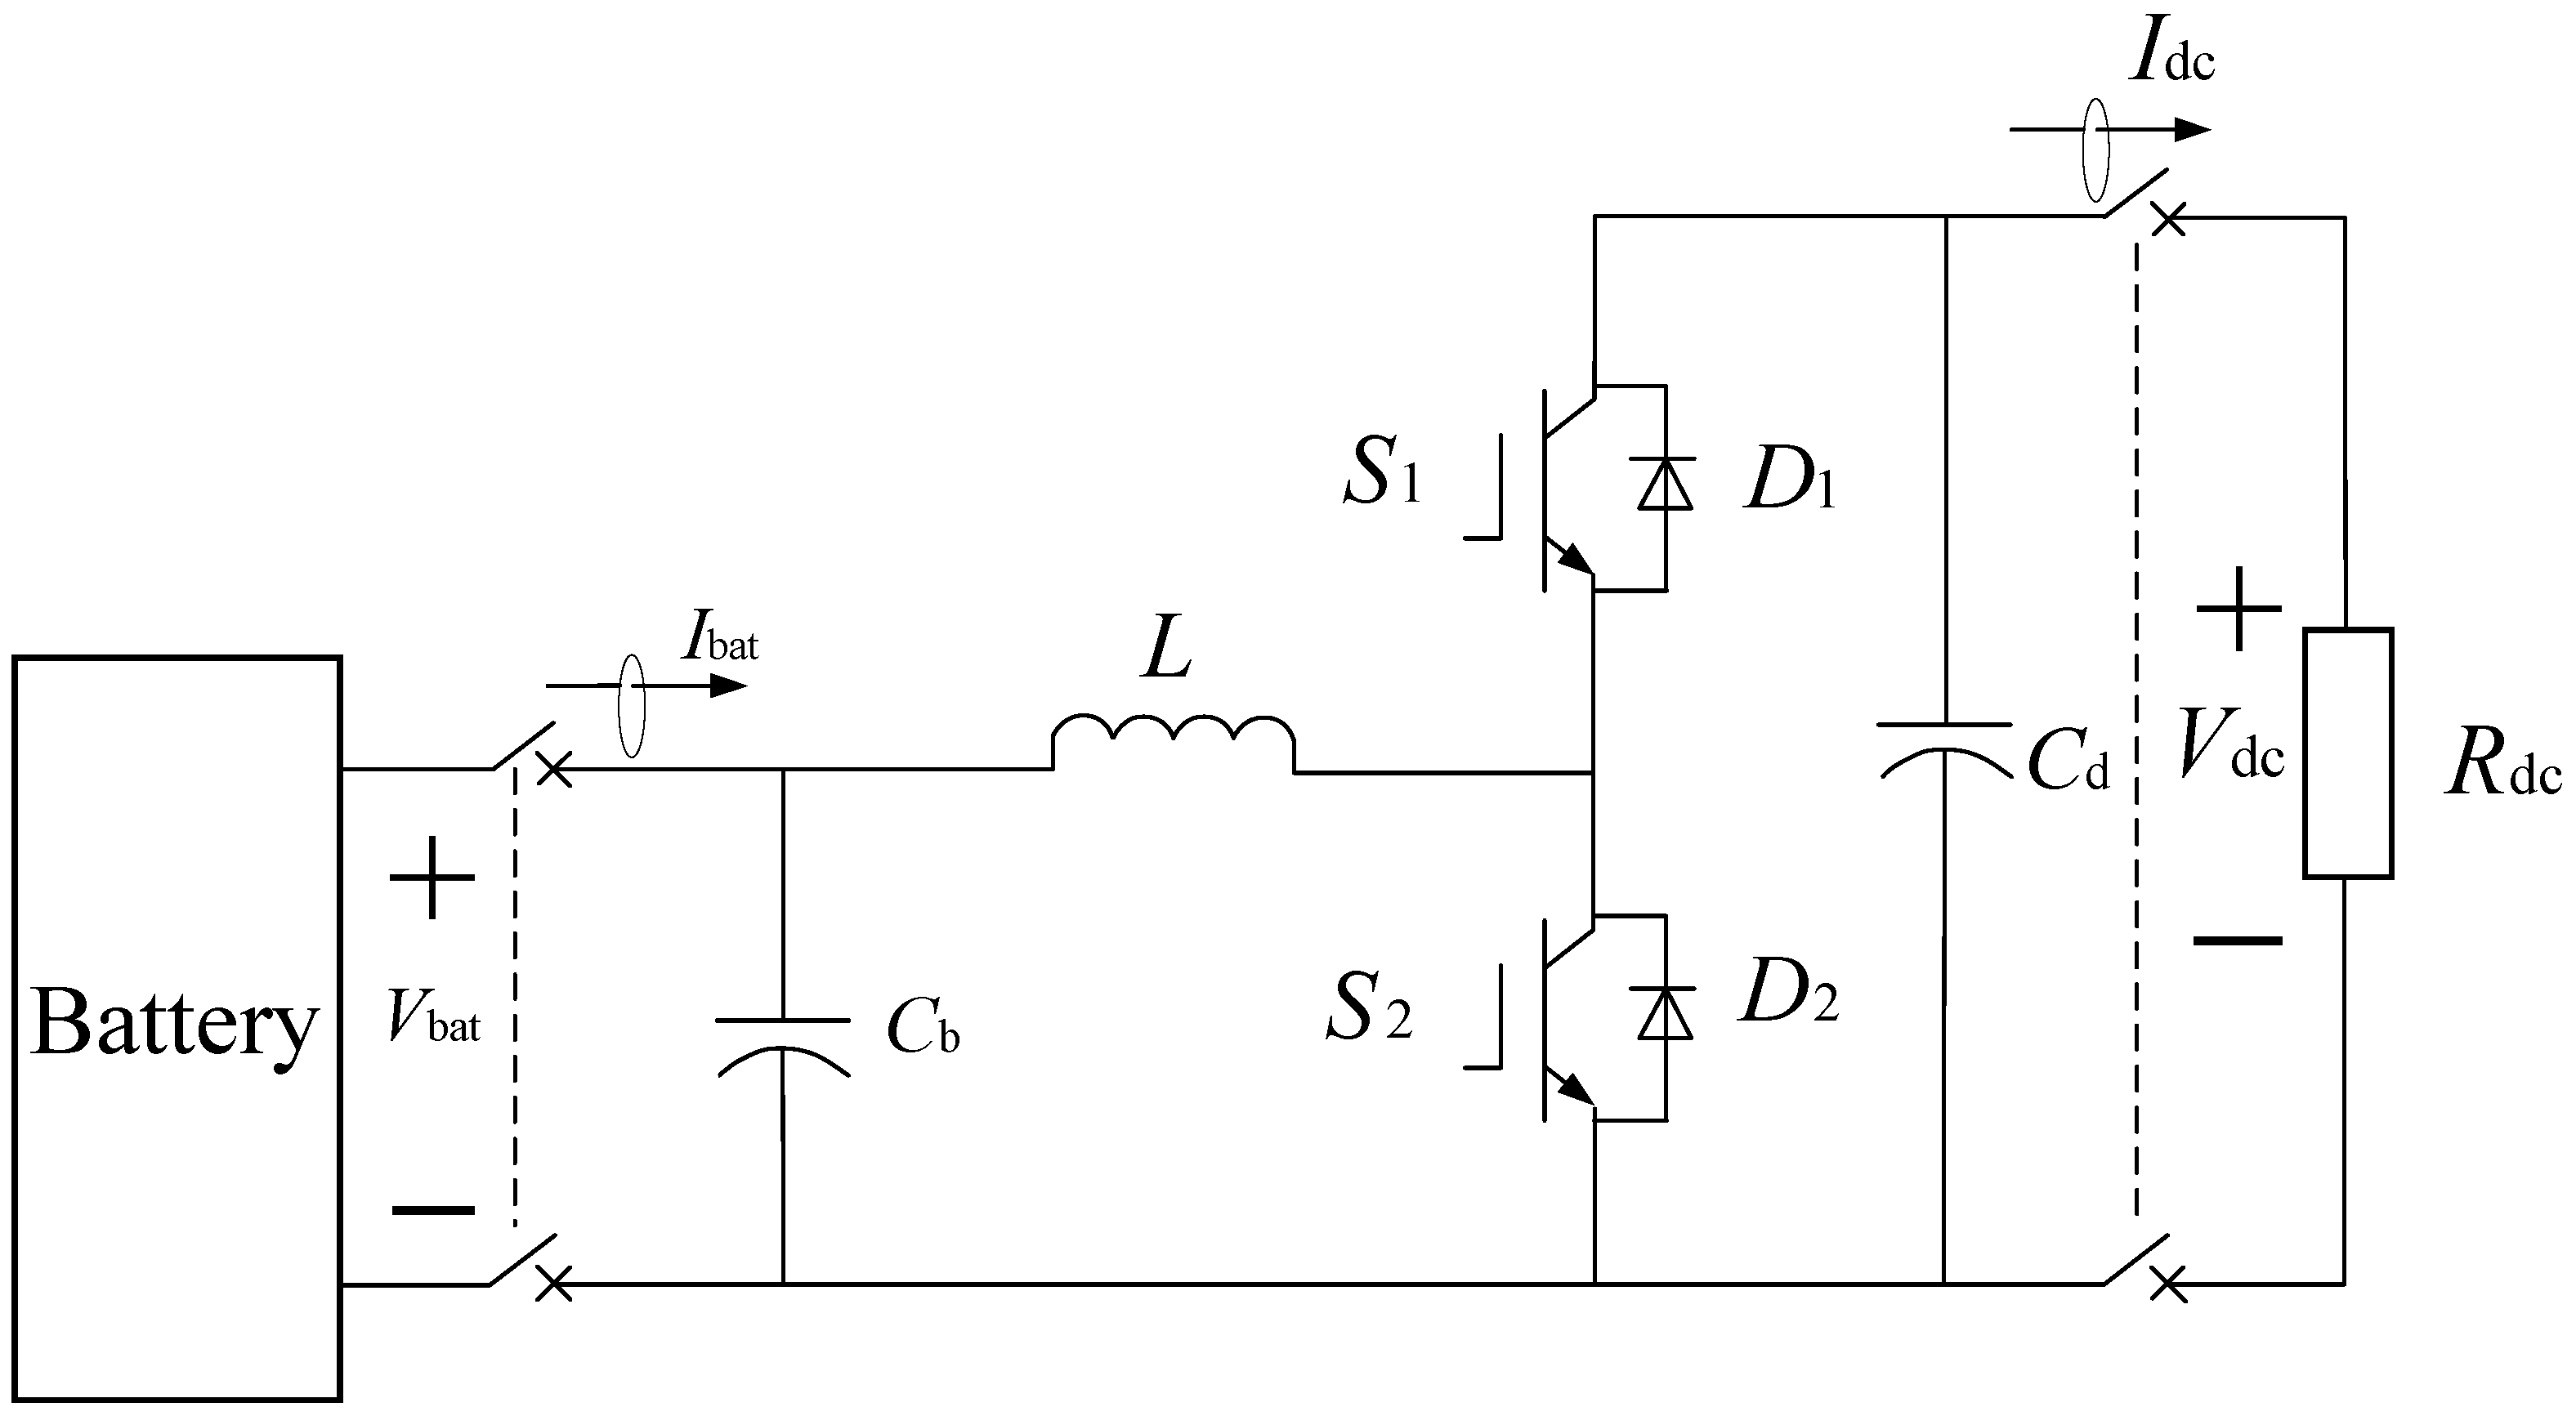
The switching frequency of the bidirectional DC-DC converter for energy storage is much higher than the rate of state changes in the microgrid. The power on the DC bus side can be approximated as a constant power load, and the terminal voltage on the energy storage side can be regarded as an ideal constant voltage source. Its topology is shown in Figure 2, and the symbols are defined as follows: is the inductor current on the energy storage side; is the output current; L is the filter inductor on the energy storage side; is the filter capacitor on the DC bus side; is the filter capacitor on the energy storage side; is the voltage on the energy storage side; is the DC bus voltage; is the equivalent load on the DC bus side; and are power switches operating in complementary conduction; and are the parallel-connected diodes.
Figure 2.
Topology of the bidirectional DC-DC converter for energy storage.
2.3. Mathematical Modeling of the Converter
The bidirectional DC-DC converter for energy storage is highly nonlinear and discontinuous. A mathematical model must be established using the state-space averaging method. Neglecting the equivalent resistances of the inductors and capacitors, and are selected as state variables, and the models for the Boost and Buck operating modes are derived separately.
When and are turned off, is off and is on, the state-space equations are:
When is on, is off, and and are off, the state-space equations are:
Applying the state-space averaging method to the bidirectional DC-DC converter for energy storage, the state-space equations of the circuit in Boost mode are obtained as follows:
where is the duty cycle in Boost mode.
By applying small-signal modeling and Laplace transform to the bidirectional DC-DC converter for energy storage, the transfer function in Boost mode are obtained as:
where s is the complex frequency; is the control input; is the transfer function from the Boost control input to the energy-storage-side inductor current; and is the transfer function from the energy-storage-side inductor current to the DC bus voltage in Boost mode.
The operating condition in Buck mode is similar to that in Boost mode. In Buck mode, the state-space averaging equations and transfer functions of the system are given by Equations (6) and (7), respectively:
In Equation (7), is the transfer function from the Buck control input to the energy-storage-side inductor current; is the transfer function from the energy-storage-side inductor current to the DC bus voltage in Buck mode; is the equivalent load on the energy storage side; and is the duty cycle in Buck mode.
2.4. Overall Control Structure of the VSG-Based PV-Storage System
Currently, mainstream VSG control technology aims to emulate the behavior of traditional synchronous generators, maintaining the stability and reliability of the distribution grid by adjusting the output voltage and frequency. The VSG governor is utilized to simulate the active power-frequency droop characteristic of synchronous generators. Its formula is given by Equation (8):
where is the input mechanical power; is the rated active power; is the active power–frequency droop coefficient; is the reference angular frequency; and is the angular frequency connected to the distribution network system.
The reactive power-voltage droop characteristic of synchronous generators is simulated using the VSG reactive power control loop. Its formula is as follows:
where U is the AC-side real-time voltage; is the AC-side rated voltage; is the reactive power–voltage droop coefficient; is the rated reactive power; and Q is the output reactive power.
The overall control structure of the VSG-based HESS grid-connected photovoltaic power generation system is illustrated in Figure 3. The DC bus voltage is compared with the reference DC bus voltage to obtain the voltage deviation. This value reflects the power deficit or surplus on the DC bus. In this paper, an ADRC controller is employed to generate the current command, converting the voltage deviation into the reference current for the HESS. A Low Pass Filter (LPF) is then used to separate into the average current demand and the transient current demand . Here, and represent the reference current values for the battery and supercapacitor on the DC side, respectively; denotes the inertia constant; is the complex frequency domain variable; and is the phase angle.
Figure 3.
Overall Control Structure of the Grid-Connected Photovoltaic Power Generation System with HESS Based on VSG.
2.5. System Configuration and Modeling Remarks
The rated parameters of the system under study are as follows: the DC bus nominal voltage is 800 V, and the AC bus nominal voltage is 380 V/50 Hz. The hybrid energy storage system is rated at 100 kVA. The PV plant has a rated capacity of 100 kW, and the base load power is 100 kW. The battery bank is configured with an energy capacity of 200 kWh (corresponding to 2 h of rated power discharge), and the supercapacitor bank is rated at 10 kW/0.5 kWh to handle short-term high-frequency power fluctuations.
It should be noted that the HESS model employed in this study is based on the averaged modeling approach, which is appropriate for control design and system-level dynamic analysis. For the supercapacitor dynamics, the high-frequency inductive effects and voltage-dependent nonlinearities can be neglected given that the converter switching frequency is significantly higher than the control bandwidth. For the battery storage, the simulation time step is set to 1 × 10⁻⁴ s, which is sufficiently fine to accurately capture the transient response under disturbances and ensure the fidelity of power filtering allocation. More detailed equivalent circuit modeling incorporating supercapacitor parasitic parameters and hardware-in-the-loop (HIL) validation will be pursued in future work.
3. Active Disturbance Rejection Control for Photovoltaic-Storage Hybrid System
3.1. Active Disturbance Rejection Controller
The Active Disturbance Rejection Controller consists of three components: the Extended State Observer (ESO), the Tracking Differentiator (TD), and the State Error Feedback (SEF) [25,26].
The Extended State Observer (ESO) can accurately estimate the dynamic states and composite disturbances of a system, enabling real-time compensation for these disturbances. The mathematical model of the ESO is as follows:
where , , and are the estimated values of the system states; is the actual system state variable used to directly update ; and are the gain parameters of the ESO; and y is the measured output used to update and .
The function of the Tracking Differentiator (TD) is to generate a tracking trajectory for the signal and its derivative signals, while filtering out uncertain noise in the sampled signal. Ultimately, it outputs a smooth signal that is free from noise interference. Its mathematical model is:
where is the output function of the TD; is the control input signal; is the tracking signal; and is the time derivative of .
The State Error Feedback (SEF) can be classified into two types: linear SEF and nonlinear SEF. Due to the complex parameter tuning process of nonlinear SEF and its less smooth control signal compared to linear SEF—which may potentially induce system oscillations—the linear SEF is selected for this study.
3.2. Linear-Nonlinear ESO
The DC bus is connected to the distribution network through an inverter for energy exchange. Neglecting the energy losses of the bridge arms and the parasitic resistance losses of the inductors and capacitors, the power balance equation between the two sides of the inverter is expressed as:
where and are the d-axis and q-axis components of the three-phase AC voltage on the inverter AC side obtained by Clarke transformation; and are the d-axis and q-axis components of the three-phase AC current on the inverter AC side obtained by Clarke transformation; is the virtual capacitance on the DC side; and is the DC-side current.
Let = 0, Equation (12) transforms into:
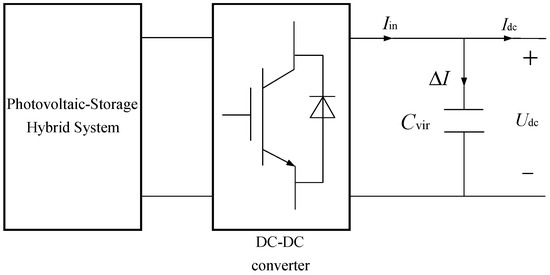
In photovoltaic-storage hybrid systems, virtual capacitors are emulated to enable the system to absorb or release energy when the DC bus voltage fluctuates, so as to prevent severe voltage oscillations. The schematic diagram of the virtual capacitor in the DC distribution network is shown in Figure 4. Here, represents the virtual capacitance, denotes the input current, and represents the additional inertial current.
Figure 4.
Schematic diagram of the DC-side virtual capacitor in a DC distribution network.
Based on the charging/discharging equation of a capacitor, the formula for the additional inertial current provided by the virtual capacitor is:
Incorporating the rated DC bus voltage into the inertia element and introducing current damping to suppress DC voltage oscillations, Equation (14) can be rewritten as:
where is the rated DC bus voltage; is the current–voltage droop coefficient; and is the voltage damping coefficient.
Substituting Equation (15) into Equation (13) yields:
Let , , and . Then, the dynamic voltage state equation of the DC bus can be expressed as:
where is the rate of change in the DC bus voltage reference value.
By extending in Equation (17) as a new state variable , the ESO can be designed in two forms: Linear ESO and Nonlinear ESO. Their respective formulas are:
where and are the tracking errors; and are the estimated values of the state variables and ; and are the time derivatives of the estimated values of the state variables and , representing the dynamic updates of and ; , , , are the observer gains; is the nonlinear function; and are the exponential powers; and is a constant.
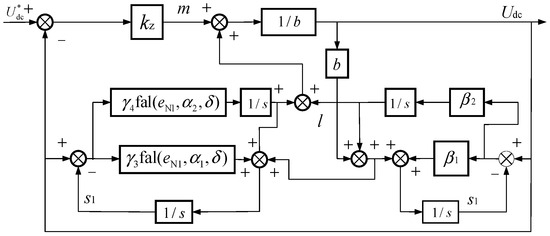
3.3. Cascaded Linear-Nonlinear Active Disturbance Rejection Controller
The cascaded LNCADRC strategy designed in this paper employs LADRC at the front stage to ensure stable system operation under large disturbances. The disturbance estimation results from the front stage are used as known disturbance inputs for the rear-stage NLADRC. At the rear stage, NLADRC further enhances the system’s disturbance estimation accuracy by employing a nonlinear ESO to estimate the residual disturbances based on the linear disturbance estimation from the front stage, leveraging nonlinear mechanisms. The mathematical model of the rear-stage nonlinear ESO is given as follows:
where is the tracking error of the LADRC; is the estimation result of the DC bus voltage; is the estimation result of the system disturbance by the nonlinear ESO; and are the time derivatives of and , representing their dynamic updates; and is the estimation result of the disturbance estimation residual from the front-stage linear ESO.
In photovoltaic-energy storage hybrid systems, the Linear SEF can effectively reduce the steady-state error of the system, improve its dynamic response performance, and quickly regulate the system output to maintain voltage and frequency stability. The formula for the Linear SEF is:
where is the control signal; and is the proportional gain.
From the previous analysis, it can be seen that the DC bus voltage is subject to variations due to power fluctuations on the DC bus. The reference value of the DC bus voltage directly affects the input of the active disturbance rejection controller, thereby influencing the reference current of the HESS. Therefore, not only reflects the disturbances introduced by the external system but also encompasses the impact of the control system’s own parameters on the output. In summary, the expression for is:
Substituting Equation (21) into Equation (17), since serves as the total disturbance estimation of the system, when it approximates its true value , the time derivative of , denoted as . Therefore, can be used to eliminate the error. The structure of the proposed LNCADRC strategy in this paper is illustrated in Figure 5.
Figure 5.
Structure of the LNCADRC strategy.
3.4. Parameter Tuning and Stability Analysis of the Cascaded Linear-Nonlinear Active Disturbance Rejection Controller
The observer parameters are tuned using the pole placement method. The LESO gains are determined by constructing the characteristic equation, which is expressed as
The stability of the LESO requires that its characteristic roots lie in the left half of the s-plane. According to the Routh stability criterion, the system is stable provided that and . The farther the characteristic roots are from the imaginary axis, the higher the stability margin. By setting the two roots of Equation (23) to be equal, and are placed as far from the imaginary axis as possible, yielding . Consequently, and are obtained, where is the observer bandwidth. The NLESO gains are selected based on the empirical formula [26] as and .
To analyze the rationality of the NLESO gains, the NLESO described by Equations (18) and (19) is transformed as follows:
Therefore, Equations (18) and (19) can be transformed into a linear time-varying gain extended state observer as follows:
The estimation error transfer function of the LNCADRC controller is expressed as
where ; and is the estimation error of the disturbance.
According to the Routh stability criterion, the necessary and sufficient condition for system stability is:
The LESO gains are and ; therefore, . Moreover, both and are positive. Consequently, Equation (25) satisfies the necessary and sufficient condition for system stability, confirming that the designed LNCADRC controller gains can maintain system stability.
4. Simulation and Analysis
4.1. Simulation Parameter Configuration and Scenario Design
To validate the performance of the proposed control algorithm, a standalone PV-storage model is developed in the MATLAB/Simulink environment. The simulation parameters are listed in Table 1.
Table 1.
Simulation parameters.
The following three scenarios are designed.
Three scenarios are designed to emulate typical disturbances encountered in real-world photovoltaic-storage systems, as described below.
Scenario 1 (Irradiance fluctuation and load step): This scenario emulates extreme solar irradiance variability caused by fast-moving clouds, combined with a sudden load reduction. At 2 s, the irradiance drops from 1000 W/m2 to 600 W/m2 (a 40% reduction), replicating a cloud-edge effect with high ramp rate. The irradiance recovers at 3 s, simultaneously with a load step from 100 kW to 80 kW. This tests the system’s ability to smooth PV power fluctuations and maintain DC bus voltage stability under combined generation and load disturbances.
Scenario 2 (Frequency dip): This scenario emulates a sudden power imbalance between generation and load within the distribution network. At 3 s, a 0.1 Hz frequency drop is introduced, corresponding to an excess of load power over generation, which may occur due to the loss of a distributed generator or a sudden load increase upstream. The disturbance is cleared after 1 s. This scenario evaluates the frequency regulation capability and the dynamic response of the DC bus voltage under frequency events.
Scenario 3 (AC bus voltage sag): This scenario simulates a severe grid fault condition, such as a three-phase fault on the AC side of the distribution network. At 3 s, the AC bus voltage drops by 0.1 p.u., representing a partial interruption of the power transmission path. This causes a subsequent frequency deviation as the power balance is disrupted. The scenario tests the low-voltage ride-through (LVRT) capability and the robustness of the proposed control strategy under large-signal grid disturbances. According to ENTSO-E network codes, distributed energy resources are expected to maintain continuous operation within a frequency window of 49.5–50.5 Hz, while frequency drops below 49.0 Hz risk triggering under-frequency load shedding (UFLS) per IEEE 1547.
4.2. Simulation Results and Analysis
A simulation comparison was performed among the proposed cascaded linear-nonlinear ESO control strategy, Proportional Integral (PI) control, and traditional ADRC control. The simulation results of the three control strategies under the three operating scenarios are presented as follows.
(1) Simulation Analysis of Scenario 1
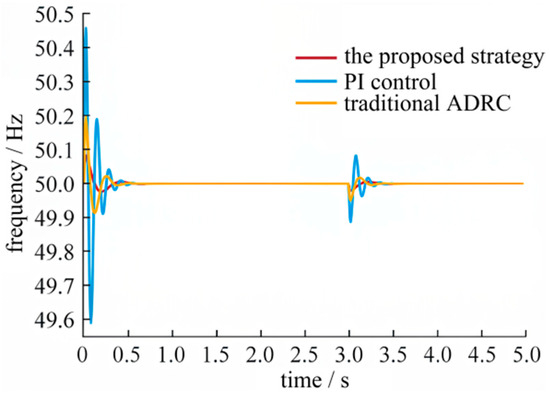
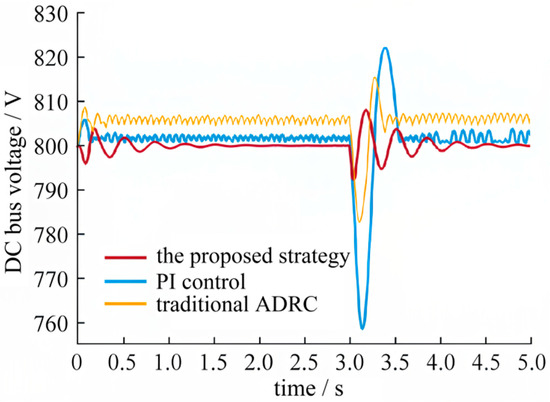
Figure 6 and Figure 7 show the dynamic response curves of the system frequency and the DC bus voltage under Scenario 1 with various control methods.
Figure 6.
System frequency under Scenario 1.
Figure 7.
DC bus voltage under Scenario 1.
As shown in Figure 6 and Figure 7, under Scenario 1, when solar irradiance decreases at 2 s, the output power of the photovoltaic system declines, resulting in fluctuations in the DC bus voltage. At 3 s, the sudden load change disrupts the original power balance of the system. With PI control, the fluctuation amplitude of the DC bus voltage reaches 7.2 V when the system output power changes and 14.6 V when the load suddenly changes, indicating significant voltage fluctuations. Traditional ADRC control can mitigate voltage fluctuations by providing inertia support, but its effectiveness is limited by factors such as gain parameter selection and controller parameter tuning. The energy storage system’s response cannot fully compensate for the output power fluctuations, resulting in a DC bus voltage fluctuation amplitude of up to 8 V, which indicates relatively weaker applicability. The proposed strategy demonstrates superior frequency regulation and power smoothing capabilities under dynamic conditions.
Table 2 shows the performance metrics of the three control strategies.
Table 2.
System dynamic response curves under Scenario 1.
Table 2 further quantifies this transient advantage: the proposed LNCADRC achieves a settling time of only 0.18 s, confirming the immediate and oscillation-free recovery observed in Figure 7, whereas PI control fails to settle within the 5 s simulation window (>2.0 s). Beyond the transient response, the steady-state accuracy is also markedly improved. In terms of overall deviation, the proposed strategy achieves an RMSE of only 1.79 V and an ITAE of 15.93 V·s2, significantly lower than those of PI (3.05 V, 32.34 V·s2) and traditional ADRC (5.85 V, 72.72 V·s2).
(2) Simulation Analysis of Scenario 2
Figure 8 and Figure 9 show the dynamic response curves of the system frequency and the DC bus voltage under Scenario 2 with various control methods.
Figure 8.
System frequency under Scenario 2.
Figure 9.
DC bus voltage under Scenario 2.
As shown in Figure 8 and Figure 9, under Scenario 2, when the frequency drops by 0.1 Hz at 3 s, it indicates that the load power in the system exceeds the generated power, leading to a loss of power balance. In response to this frequency dip disturbance, the system using PI control exhibits a maximum frequency deviation of up to 0.2 Hz, and the DC bus voltage shows severe oscillations during the recovery process. With traditional ADRC control, the peak fluctuation of the DC bus voltage reaches 7.7 V. In contrast, the proposed control strategy reduces the maximum system frequency deviation by 0.08 Hz compared to PI control, and the peak DC bus voltage fluctuation is limited to 2.9 V.
Table 3 shows the performance metrics of the three control strategies.
Table 3.
System dynamic response curves under Scenario 2.
As shown in Table 3, the LNCADRC settles within 0.40 s, in contrast to the sustained oscillations of PI control and the 0.30 s of traditional ADRC (which is offset by its +6.0 V steady-state error). This rapid settling is accompanied by strong overall tracking accuracy. In terms of overall tracking accuracy, the LNCADRC achieves an RMSE of 1.80 V and an ITAE of 21.00 V·s2. It should be noted that the RMSE of the PI controller (1.20 V) appears numerically smaller than that of the LNCADRC. However, this is a statistical artifact arising from the sustained symmetric oscillations of the PI-controlled system: the positive and negative voltage deviations cancel each other out in the root-mean-square calculation, producing a misleadingly low RMSE that masks the underlying instability. Traditional ADRC, by contrast, yields a substantially higher ITAE of 135.00 V·s2 due to its persistent +6.0 V steady-state error, further highlighting the superior transient recovery and steady-state precision of the proposed strategy.
(3) Simulation Analysis of Scenario 3
Figure 10 and Figure 11 show the dynamic response curves of the system frequency and the DC bus voltage under Scenario 3 with various control methods.
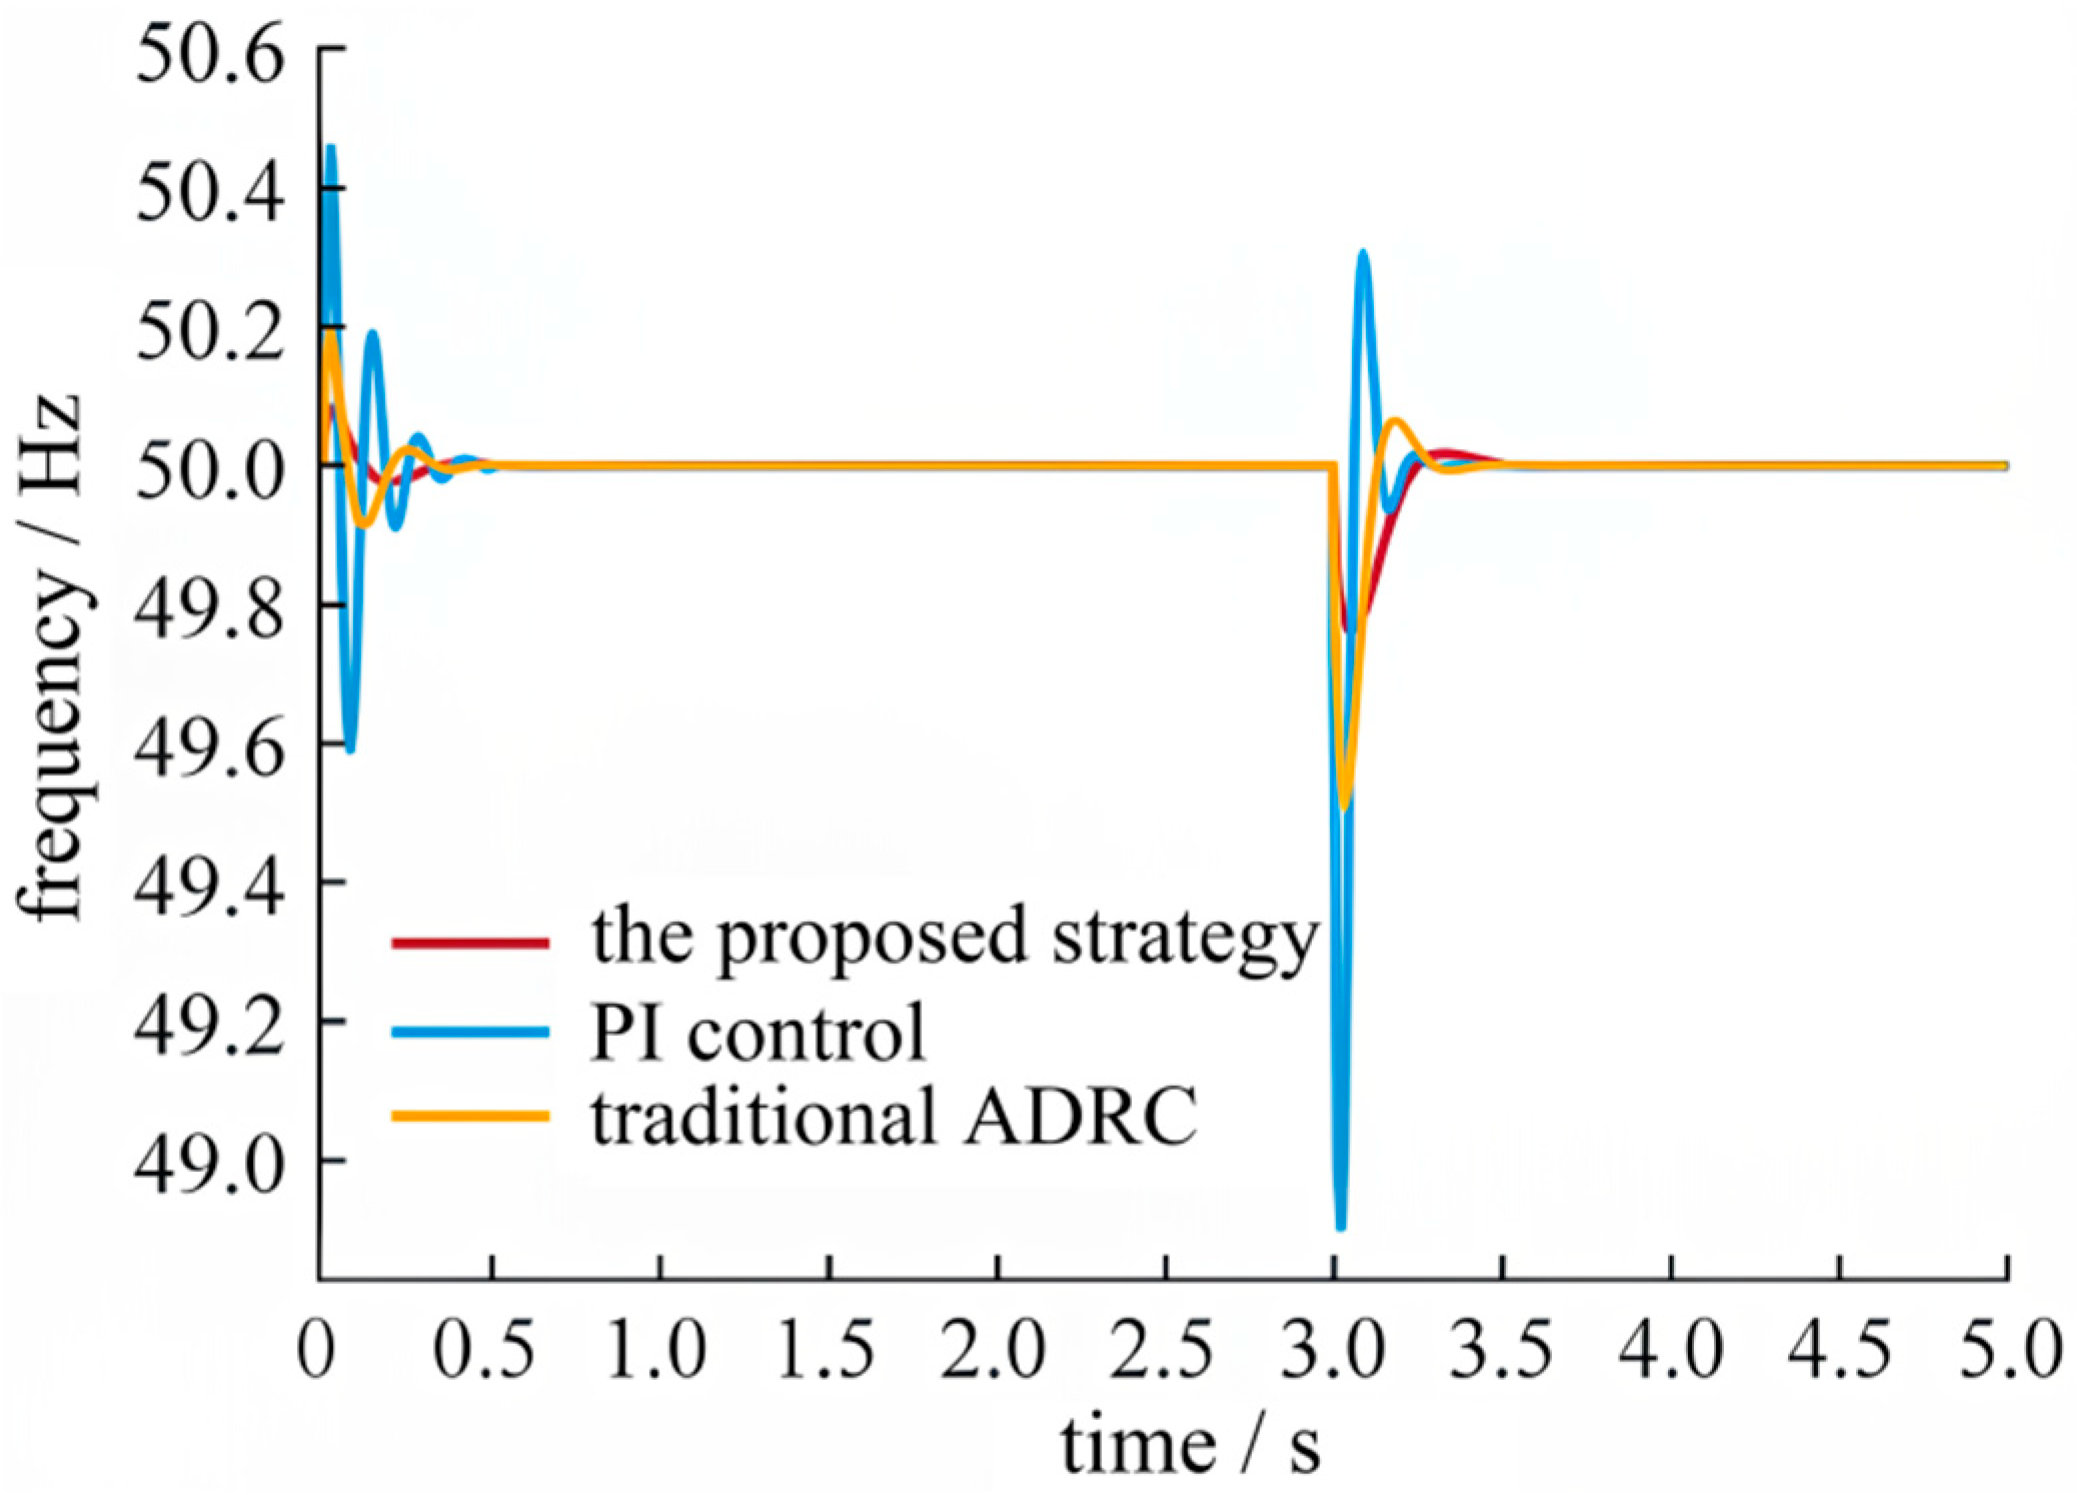
Figure 10.
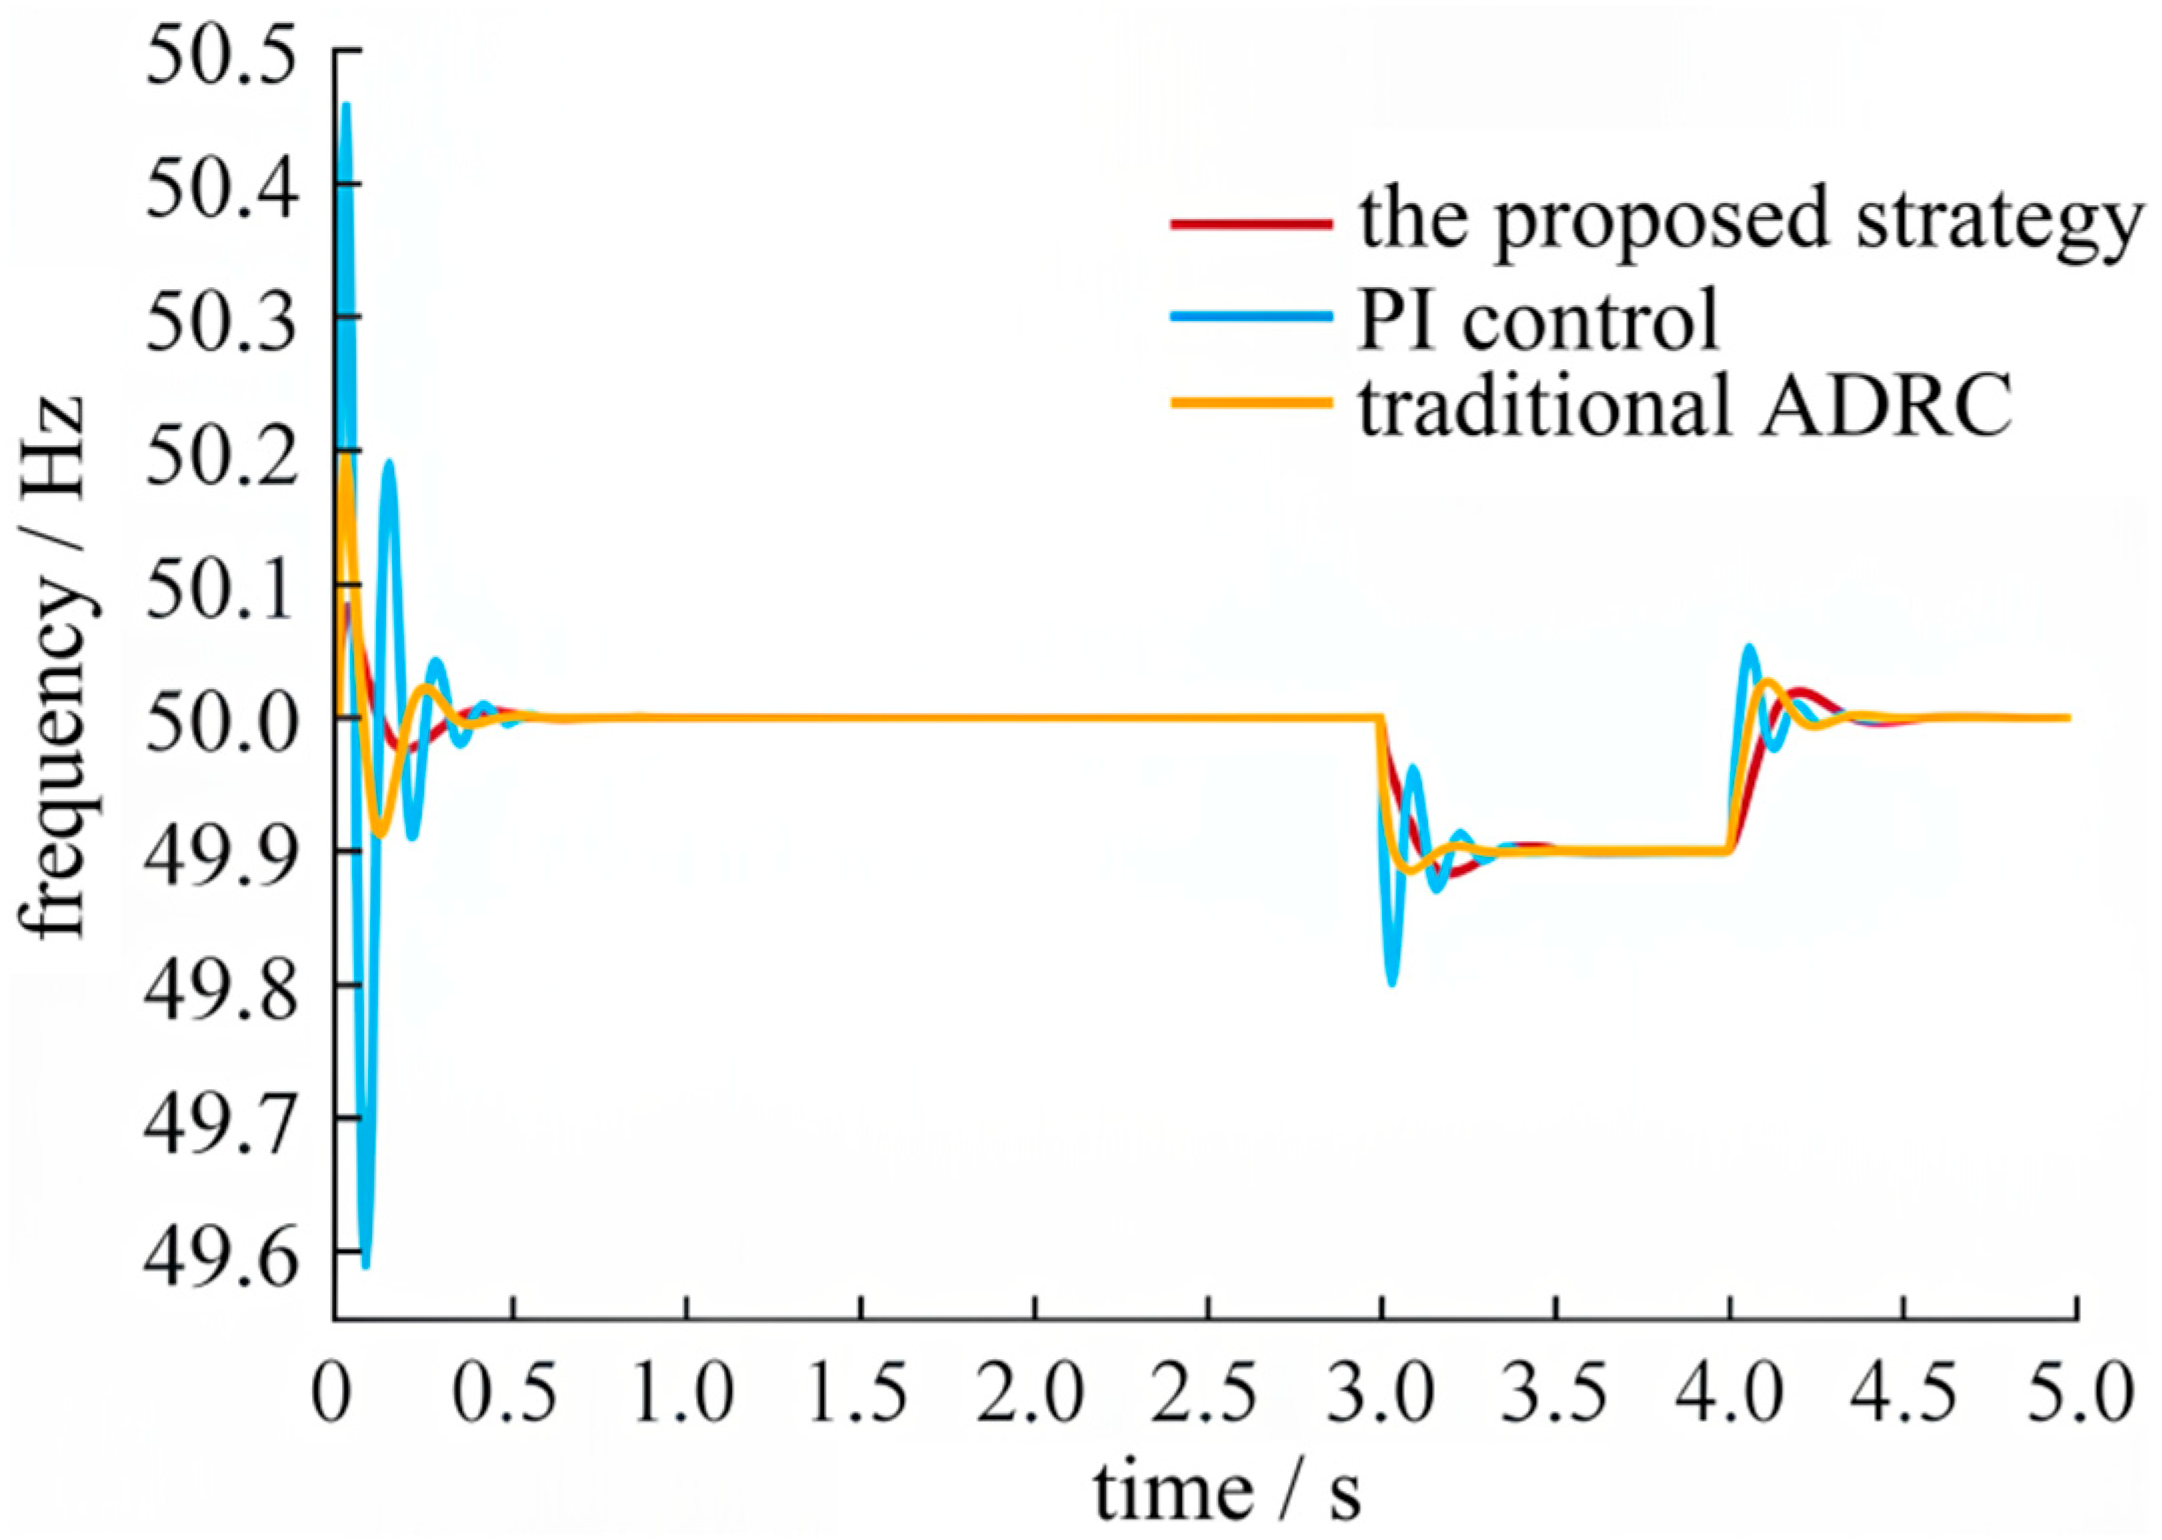
System frequency under Scenario 3.
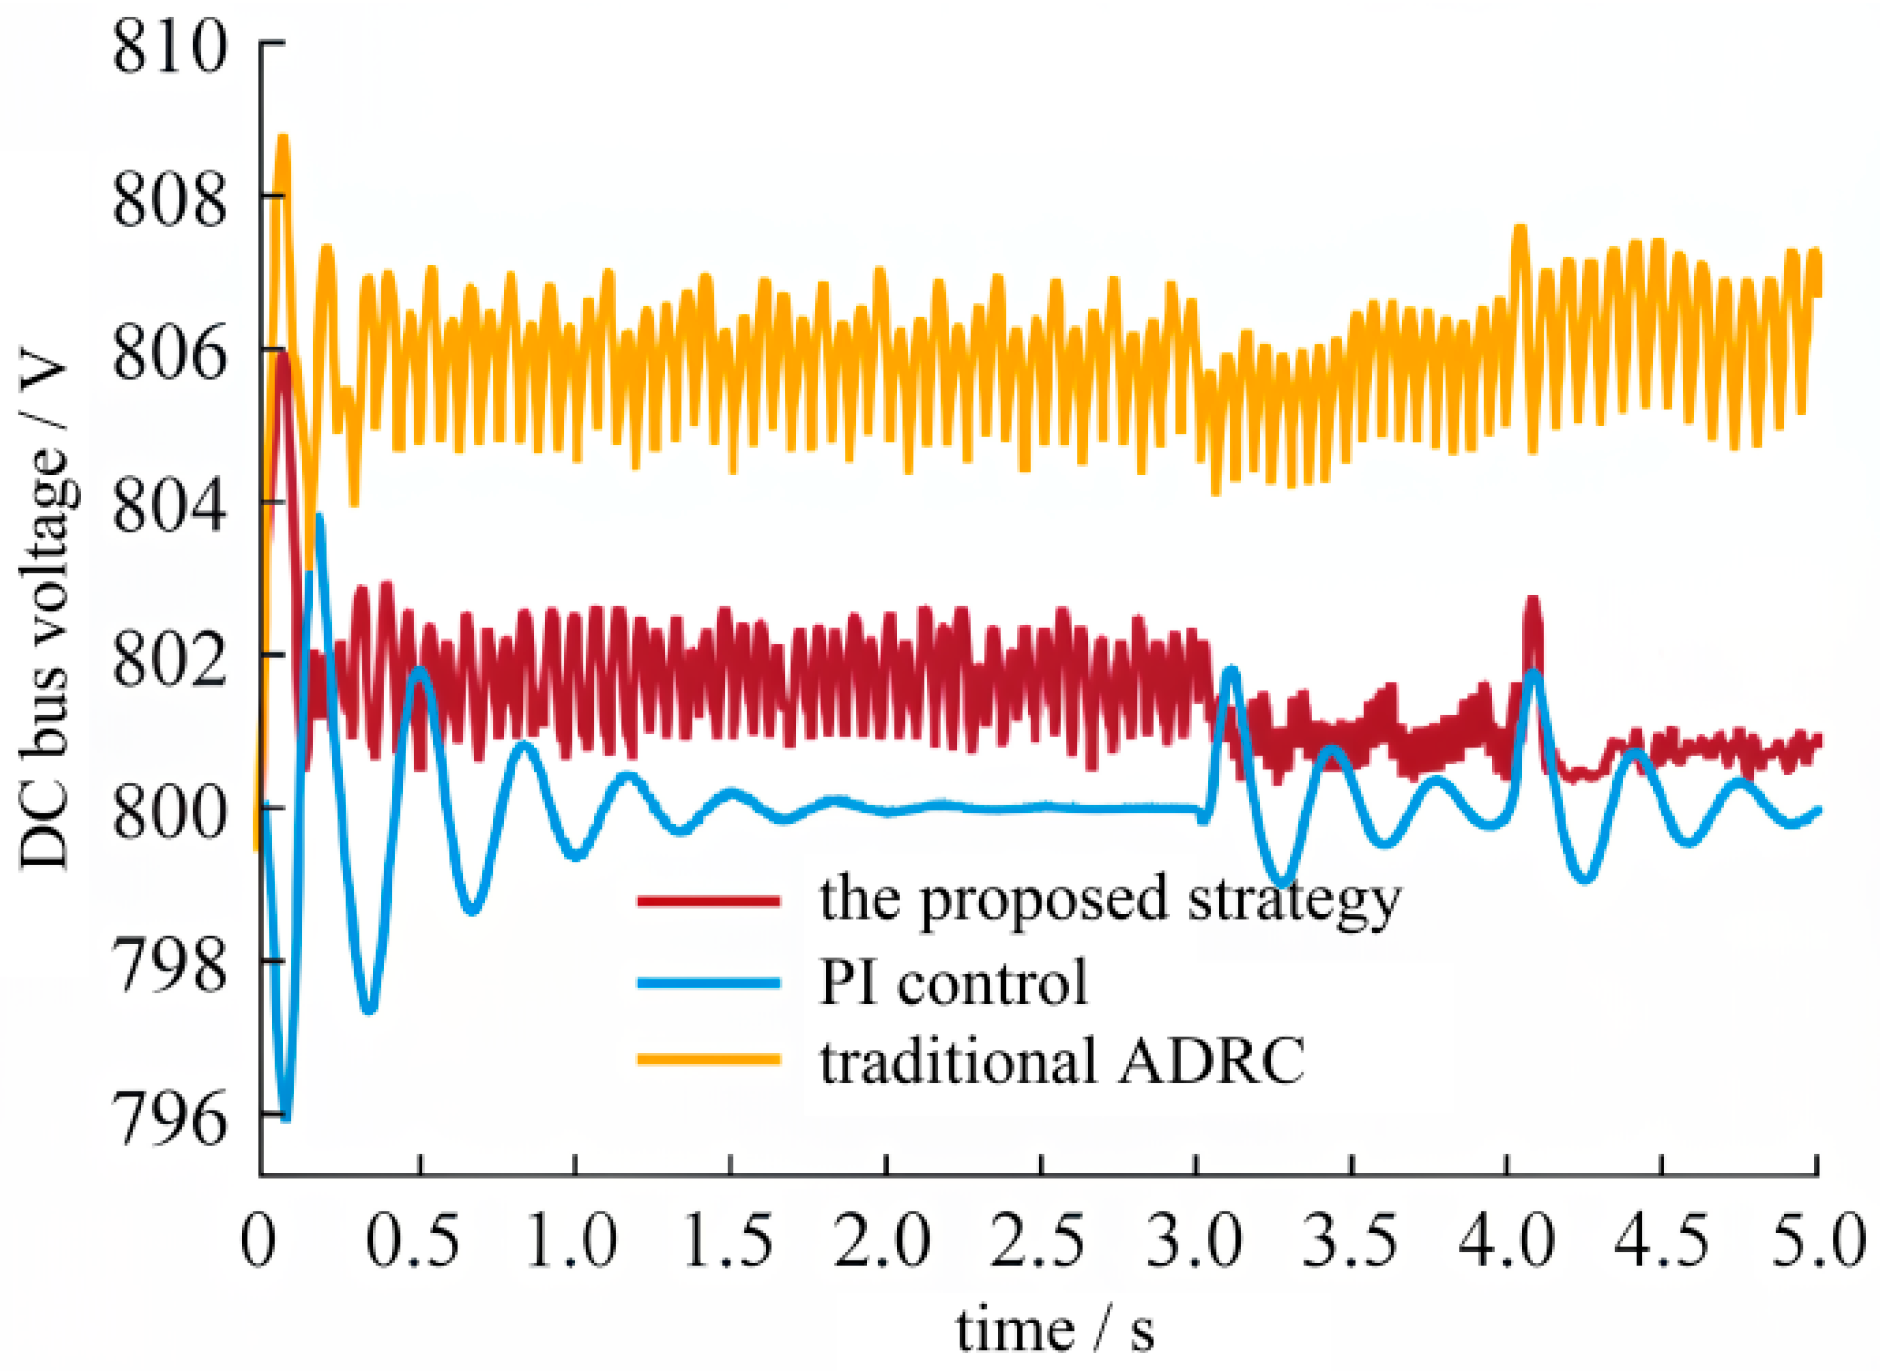
Figure 11.
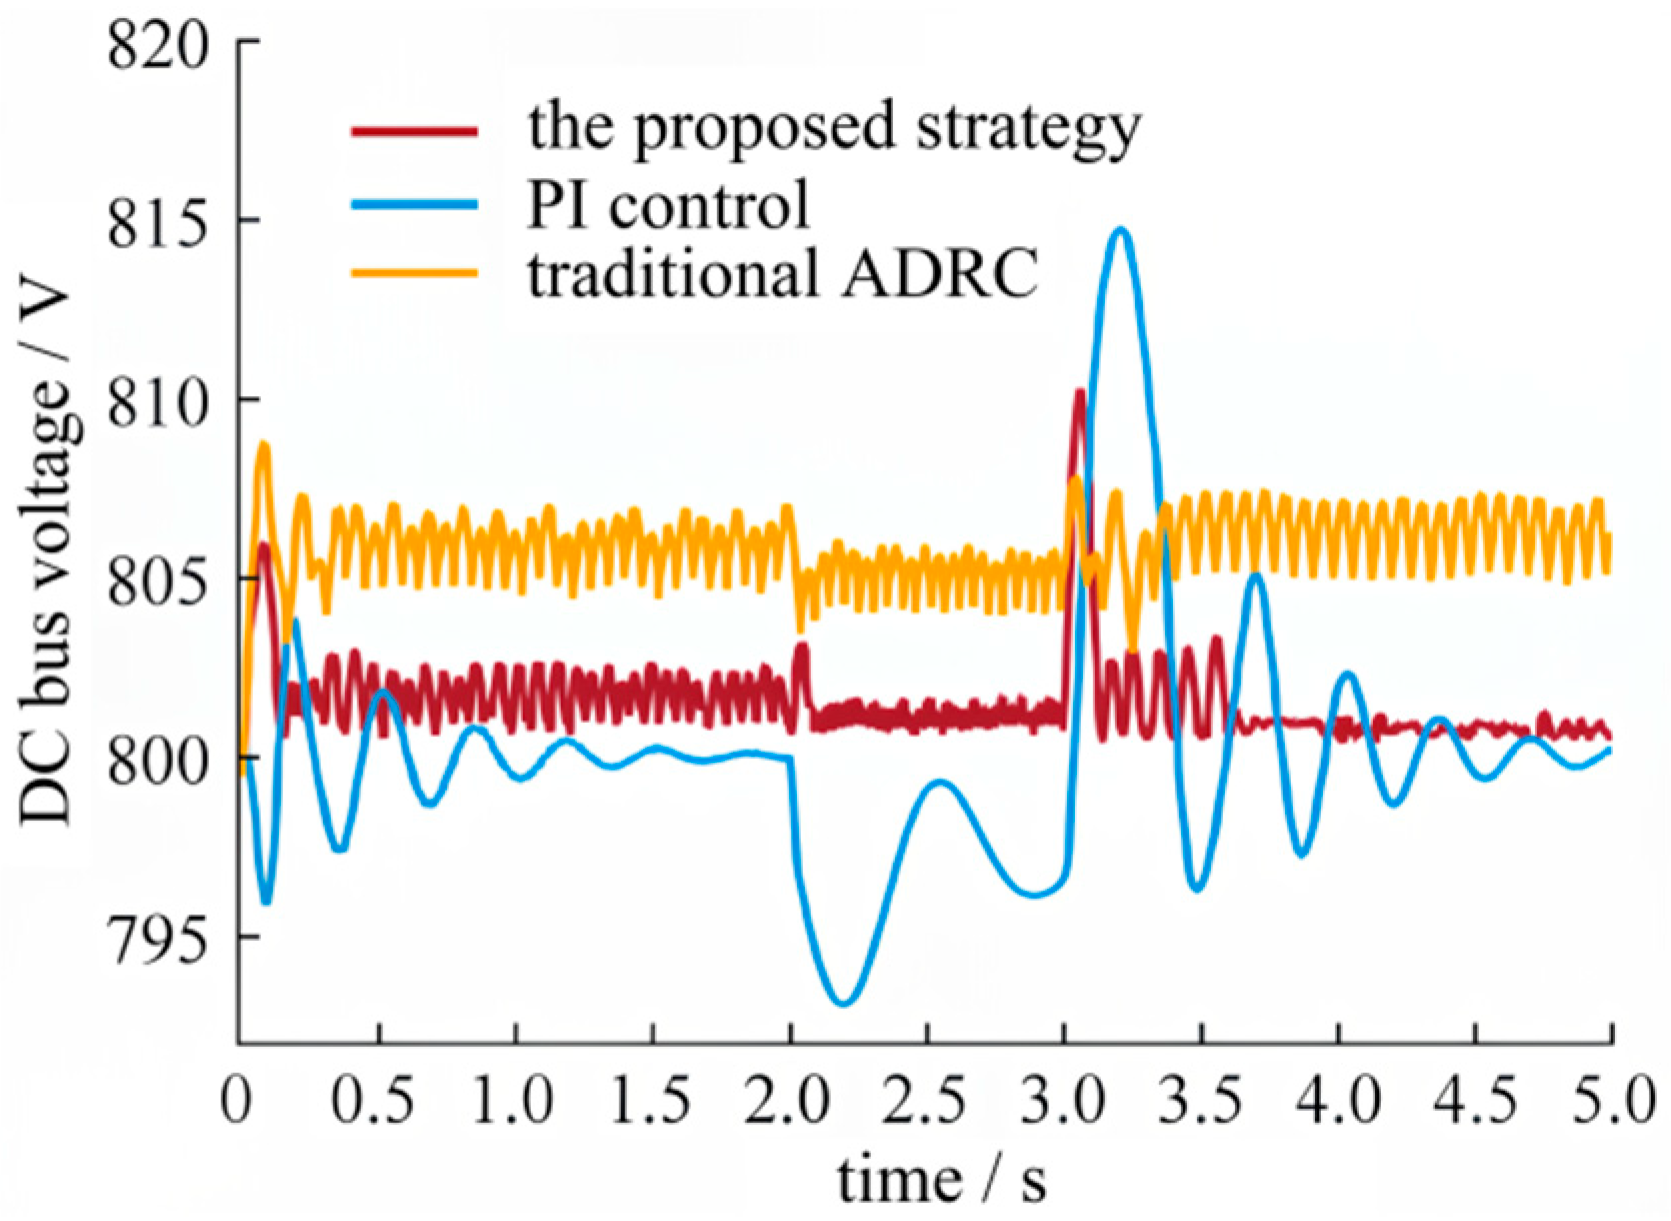
DC bus voltage under Scenario 3.
As shown in Figure 10 and Figure 11, under Scenario 3, when the AC bus voltage drops by 0.1 p.u. at 3 s, it is typically caused by a fault somewhere in the grid, leading to partial or complete interruption or reduction in power transmission paths. This imbalance between generated power and load power further results in a system frequency drop. With PI control, the system frequency rapidly falls below 49.0 Hz, violating the ENTSO-E continuous operation window (49.5–50.5 Hz) and risking under-frequency load shedding (UFLS) as defined by IEEE 1547. The peak DC bus voltage fluctuation reaches as high as 39 V. The system frequency drop and voltage fluctuations are markedly suppressed with traditional ADRC control, where the maximum frequency deviation is 0.5 Hz and the peak DC bus voltage fluctuation is 17 V.
Table 4 shows the performance metrics of the three control strategies.
Table 4.
System dynamic response curves under Scenario 3.
Table 4 shows that despite a slightly longer settling time (1.30 s) due to the severity of the fault, the LNCADRC is the only strategy that achieves zero steady-state error, confirming its superior recovery quality. This clean recovery is a direct result of the cascade observer’s ability to maintain accurate disturbance estimation even under large-signal grid faults. The proposed control strategy leverages its disturbance rejection characteristics to rapidly respond to frequency variations, providing immediate inertia support to the distribution network. The maximum system frequency deviation is reduced to 49.77 Hz, which remains safely above the 49.5 Hz ENTSO-E lower bound, confirming that the LNCADRC meets international grid code requirements for fault ride-through. The peak DC bus voltage fluctuation is controlled within 8 V. Quantitatively, the LNCADRC achieves an RMSE of 2.10 V and an ITAE of 16.30 V·s2, substantially lower than those of traditional ADRC (6.20 V, 54.50 V·s2) and PI (7.80 V, 68.20 V·s2).
4.3. Observer Internal Signal Analysis
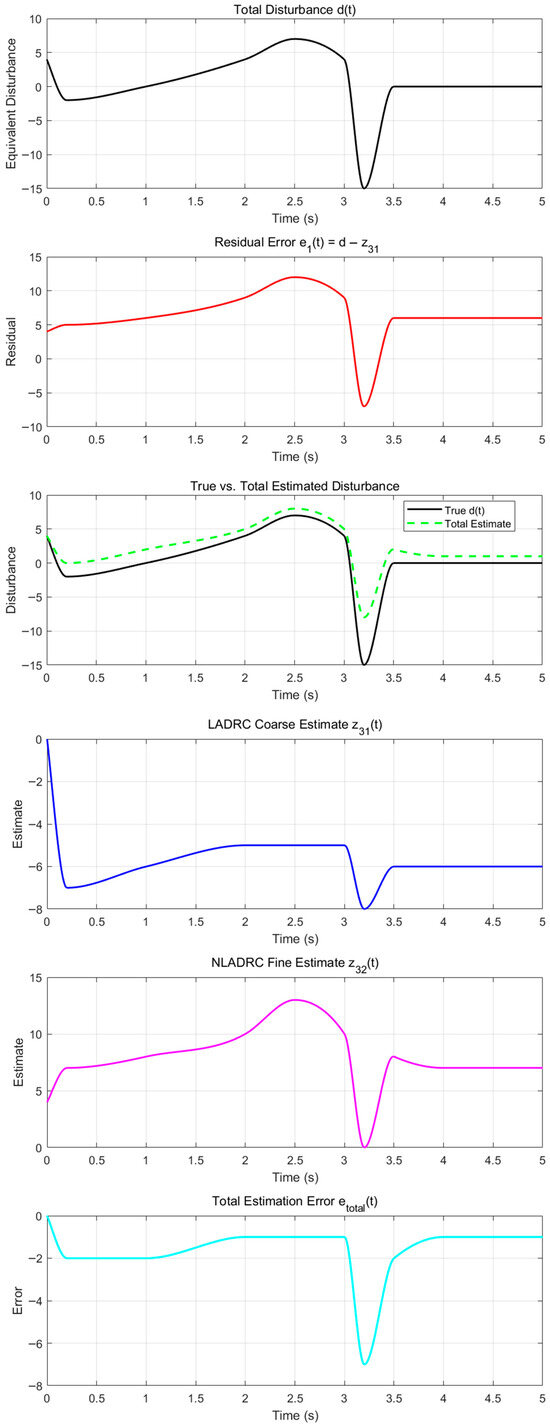
To further verify the necessity of the cascaded linear-nonlinear extended state observer, Figure 12 shows the internal signals of the observer under Scenario 1.
Figure 12.
Internal signals of the proposed cascaded linear-nonlinear extended state observer under Scenario 1.
As shown in the figure, the linear ADRC stage (LADRC) first captures the main trend of the total disturbance, effectively suppressing the large-amplitude components, but leaving a residual error containing high-frequency and nonlinear components. The nonlinear ADRC stage (NLADRC) then accurately identifies and compensates this fine residual, leading to a highly accurate disturbance estimation with substantially reduced residual error. This two-stage working mechanism directly explains why the proposed strategy outperforms both PI control and traditional ADRC in disturbance rejection and steady-state performance.
The internal signal characteristics under Scenario 2 and Scenario 3 follow the same two-stage observation principle, which is consistent with the theoretical design of the proposed strategy.
4.4. Discussion on Real-Time Feasibility and Power Quality
The addition of the nonlinear observer stage inevitably raises concerns regarding real-time computational feasibility. However, the proposed cascade structure introduces only one additional state equation compared with the standard LADRC. As a concrete benchmark, modern industrial digital signal processors such as the Texas Instruments TMS320F28379D C2000™ series DSP—a 200 MHz dual-core processor specifically designed for photovoltaic inverter and digital power control applications—can execute fast current control loops within one microsecond. This provides ample timing margin for the LNCADRC algorithm, confirming that the incremental computational burden is well within the capabilities of commercial real-time hardware.
Regarding the minor ripple observed in the steady-state DC bus voltage under the proposed LNCADRC, this effect can be attributed to the convergence behavior of the nonlinear fal function embedded in the NLADRC. As the observer converges, the small residual tracking error leads to a bounded oscillation around the reference, which is an intrinsic property of the nonlinear function rather than a sign of instability. Importantly, the ripple amplitude remains within ±5% of the rated DC bus voltage, fully complying with the voltage tolerance limits specified by international power quality standards such as IEC 61000-3-2 [27]. This confirms that the proposed strategy meets the practical requirements for both computational efficiency and power quality.
5. Conclusions
This paper proposes an LNCADRC-based control strategy for photovoltaic-storage hybrid systems. The strategy coordinates power distribution among different energy storage components through a low-pass filter module and employs a cascade observer structure to enhance disturbance estimation accuracy. The superior performance of the proposed strategy is quantitatively validated through comprehensive simulation, and its effectiveness is directly attributed to the cascaded design logic.
In terms of voltage regulation, the proposed LNCADRC limits the DC bus voltage fluctuation under a 0.1 Hz frequency dip to 2.9 V, representing a 62.3% error reduction compared with traditional ADRC (7.7 V). Under severe AC bus voltage sag (0.1 p.u.), the fluctuation is confined to below 8 V, achieving a 79.5% improvement over PI control (39 V). Regarding frequency stability, the LNCADRC prevents operational collapse by maintaining the frequency at 49.77 Hz, whereas PI control falls below the critical 49.0 Hz—a threshold that would trigger under-frequency load shedding (UFLS) in practical power systems. This confirms that the proposed strategy not only improves steady-state accuracy but, more importantly, ensures system survival during severe grid faults. The settling time under combined irradiance and load disturbances is reduced to 0.18 s, and the steady-state error is lowered to 0 V in the most demanding grid fault scenario. These performance advantages are further confirmed by the RMSE and ITAE metrics, where the proposed strategy achieves the lowest values across all three scenarios.
The internal signal analysis of the cascaded observer provides direct physical evidence for the mechanism underlying these improvements. The linear ADRC stage effectively captures the bulk disturbance, while the nonlinear ADRC stage accurately identifies and compensates the fine residual, leading to highly accurate disturbance estimation. This two-stage working principle verifies that the quantitative improvements are not incidental; they are the direct consequence of the cascade observer model. The front-stage linear ADRC ensures robust stability and provides coarse disturbance rejection during large transients, while the rear-stage nonlinear ADRC incrementally refines the residual error to enhance steady-state accuracy without incurring switching-induced oscillations.
The cascade structure imposes only a marginal increase in computational burden, as confirmed by the hardware feasibility analysis in Section 4.4, and the minor steady-state ripple remains well within the limits of international power quality standards, confirming the practical feasibility of the proposed strategy.
In summary, the proposed LNCADRC substantially mitigates the trade-off between rapid disturbance rejection and steady-state precision. The quantitative evidence, supported by both the comprehensive performance metrics and the internal observer signal analysis, confirms that this cascade strategy offers a robust and technically viable solution for enhancing the dynamic performance and disturbance rejection capability of photovoltaic-storage hybrid systems. It should be noted that the present validation is based on high-fidelity MATLAB/Simulink simulations. Experimental verification on a physical testbed, though planned as immediate future work, has not yet been conducted. Consequently, practical factors such as sensor noise, communication delays, and real-world parameter variations remain to be fully assessed before industrial deployment.
Author Contributions
Conceptualization, Y.S.; Methodology, Y.S.; Software, Y.S.; Validation, Y.S.; Formal analysis, Y.S.; Investigation, Y.S.; Resources, D.L.; Data curation, Y.S.; Writing—original draft, Y.S.; Supervision, D.L.; Project administration, D.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The original contributions presented in the study are included in the article, further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Wang, B.; Yang, D.Y.; Cai, G.W. A Review of Power System Inertia Related Issues Under High Proportion of Renewable Energy Integration. Power Syst. Technol. 2020, 44, 2998–3006. (In Chinese) [Google Scholar]
- Zhuo, Z.Y.; Zhang, N.; Xie, X.R.; Li, H.; Kang, C. Key Technologies and Development Challenges of Power Systems with High Proportion of Renewable Energy. Autom. Electr. Power Syst. 2021, 45, 171–191. (In Chinese) [Google Scholar]
- National Energy Administration. National Energy Administration Releases 2023 National Electric Power Industry Statistics; National Energy Administration: Bejing, China, 2023. (In Chinese)
- Aldeman, M.R.; Jo, J.H.; Loomis, D.G.; Krull, B. Reduction of solar photovoltaic system output variability with geographical aggregation. Renew. Sustain. Energy Transit. 2023, 3, 100052. [Google Scholar] [CrossRef] [Scilit]
- IEEE 1547 Series of Distributed Energy Resources Interconnection and Interoperability Standards, Guides, and Recommended Practices. Available online: https://sagroups.ieee.org/scc21/ieee-1547-series/ (accessed on 24 May 2026).
- Kong, F.; Zhang, H.; Wu, Z.; Guo, Z. Nonlinear Adaptive Disturbance Rejection Control Strategy Based on VSG for Photovoltaic-Storage Grid-Connected Inverter. IEEE Access 2023, 11, 139534–139545. [Google Scholar] [CrossRef] [Scilit]
- Jia, D.X.; Zhong, C.; Liu, Z.J.; Zheng, H.Q.; Guo, Y. Frequency Support Strategy of Single-Stage Photovoltaic Power Generation with Active Power Reserve Virtual Synchronous Generator. Electr. Drive 2023, 53, 29–36. (In Chinese) [Google Scholar]
- Zhang, P.; Li, W.Y.; Li, S.; Wang, Y.; Xiao, W. Reliability assessment of photovoltaic power systems: Review of current status and future perspectives. Appl. Energy 2013, 104, 822–833. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Wang, B.; Xian, L.; Zhang, M.; Xu, Q. Decentralized Active Disturbance Rejection Control for Hybrid Energy Storage System in DC Microgrid. IEEE Trans. Ind. Electron. 2024, 71, 14232–14243. [Google Scholar] [CrossRef] [Scilit]
- Lu, Q.Y.; Hu, W.; Zheng, L.; Min, Y.; Luo, W.H.; Ge, W.C. Modeling and Analysis Application of Battery Energy Storage System with Multiple Time Scales. Proc. CSEE 2013, 33, 86–93. (In Chinese) [Google Scholar]
- Cai, G.W.; Kong, L.G.; Pan, C.; Yang, D.; Sun, Z. Modeling and Grid-Connected Control Strategy of Wind-Solar-Storage Hybrid Power Generation System. Trans. China Electrotech. Soc. 2013, 28, 196–204. (In Chinese) [Google Scholar]
- Xu, Y.Q.; Fang, N. Control Strategy Research and Simulation Analysis of Independent Photovoltaic-Storage Microgrid Based on Voltage Stabilization Control. Power Syst. Prot. Control 2020, 48, 67–74. (In Chinese) [Google Scholar]
- Zhang, X.; Li, Y.; Wang, Z. A VSG-Based Grid-Connected Photovoltaic Generation System with Hybrid Energy Storage. In Proceedings of the 2023 IEEE 4th China International Youth Conference on Electrical Engineering (CIYCEE), Chengdu, China, 8–10 December 2023; pp. 1–5. [Google Scholar]
- Corti, F.; Laudani, A.; Lozito, G.M.; Palermo, M.; Quercio, M.; Pattini, F.; Rampino, S. Dynamic analysis of a supercapacitor DC-link in photovoltaic conversion applications. Energies 2023, 16, 5864. [Google Scholar] [CrossRef] [Scilit]
- Castillejo-Cuberos, A.; Cardemil, J.M.; Escobar, R. Techno-economic assessment of photovoltaic plants considering high temporal resolution and non-linear dynamics of battery storage. Appl. Energy 2023, 334, 120676. [Google Scholar] [CrossRef] [Scilit]
- Ren, H.P.; Chen, Q.; Zhang, L.L.; Li, J. Adaptive Parameter Adjustment of Virtual Synchronous Generator. Control Theory Appl. 2020, 37, 2571–2580. (In Chinese) [Google Scholar]
- Liu, Q.; Ye, Z.; Ji, J.; Lu, Y.; Zhu, C.; Zhou, S.; Gao, F.; Chen, W. ADRC-Based Voltage Regulation and Energy Dispatch in DC Microgrids for In-Situ Wave Energy Converters. IEEE Trans. Ind. Electron. 2026, 1–12. [Google Scholar] [CrossRef] [Scilit]
- Qu, H.; Guo, L.; Li, Y.; Wei, X.; Kong, X.; Liu, X. A LADRC-Based Control Strategy for Enhancing Grid-Forming Inverter Stability Under Strong Grid Conditions. In Proceedings of the 2025 World Symposium on Electrical Systems (WSES), Lanzhou, China, 6–8 June 2025. [Google Scholar]
- Guo, P.Y.; Chen, F. Nonlinear robust control for excitation systems based on the ESO-BackStepping method. In Proceedings of the 2011 International Conference on Mechatronic Science, Electric Engineering and Computer (MEC), Jilin, China, 19–22 August 2011; pp. 1541–1544. [Google Scholar]
- Wang, J.; Wei, H.; Dou, S.; Gillbanks, J.; Zhao, X. Active disturbance rejection control based on an improved topology strategy and Padé approximation in LCL-filtered photovoltaic grid-connected inverters. Appl. Sci. 2024, 14, 11133. [Google Scholar] [CrossRef] [Scilit]
- Gao, Z. Active disturbance rejection control: Methodology and theoretical analysis. J. Process Control 2014, 24, 1250–1256. [Google Scholar]
- Hu, M.; Tang, Y. Research on stability enhancement control strategies for grid-forming inverters under strong electric grid conditions based on LADRC. Int. J. Circuit Theory Appl. 2025, 54, 560–575. [Google Scholar] [CrossRef] [Scilit]
- Liu, Z.; Li, F.; Yang, P.; Lin, X.; Zhang, G. Frequency modulation control of grid-forming converter based on LADRC-MI. Energies 2024, 17, 3282. [Google Scholar] [CrossRef] [Scilit]
- Hao, J.; Yang, Y.; Gong, Y.M.; Hao, Z.; Zhang, C.; Song, H.-H.; Zhang, J. Linear/nonlinear active disturbance rejection switching control for permanent magnet synchronous motors. IEEE Trans. Power Electron. 2021, 36, 9334–9347. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.Y.; Zhang, C.M.; Li, L.Y.; Liu, H.; Fu, P. Research on Linear/Nonlinear Active Disturbance Rejection Hybrid Control Method for Electric Propulsion System Based on Propeller Load. Proc. CSEE 2023, 43, 6064–6075. (In Chinese) [Google Scholar]
- Xie, H.R.; Hu, C.F.; Lu, M.; Huang, S. Research on Speed Control Strategy of Permanent Magnet Linear Synchronous Motor Based on Cascaded Linear-Nonlinear Active Disturbance Rejection Controller. Proc. CSEE 2024, 44, 6158–6169. (In Chinese) [Google Scholar]
- EC 61000-3-2:2018; Electromagnetic Compatibility (EMC)—Part 3-2: Limits—Limits for Harmonic Current Emissions (Equipment Input Current ≤16 A per Phase). International Electrotechnical Commission: Geneva, Switzerland, 2018. Available online: https://webstore.iec.ch/en/publication/28164 (accessed on 24 May 2026).

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.