


Abstract
Renewable energy sources in DC microgrids require high-performance conversion systems to increase their capacity and reliability. Among other characteristics in conversion systems, the current ripple is a characteristic that must be considered since it affects the performance of PV panels and batteries. In this paper, a high-voltage-gain DC–DC boost converter for performing current ripple elimination that is based on a variable inductor is proposed. The topology is composed of a diode–capacitor voltage multiplier and a modified cascaded boost converter. To achieve voltage regulation, a reduced-order switched model is obtained considering the switched capacitor’s dynamics. To address the inductance variation and external disturbances, the control theory is adapted to systematically design a robust proportional–integral (PI) controller. Details of the working principles and the sizing of passive components are presented. The simulation and experimental results demonstrate that the input current ripple of the proposed converter can be removed in both transitory and steady states.
1. Introduction
Renewable energy sources in DC microgrids, such as PV panels, wind turbines, and bio-electricity, generate electrical power via different principles; however, they generally produce low-voltage buses. High-gain power converters are required to address the low voltage problem and regulate voltage levels [1,2,3,4]. To reach an adequate voltage level, a high duty ratio in the traditional boost converter or cascaded converters is used [5]. However, the efficiency and reliability of the power converter are greatly affected.
The voltage gain must be improved via several methods without affecting the overall system operation. These methods include the use of either switched capacitors or switched inductors to store energy. In [6], a replacement methodology was proposed and categorized in four cases: a combination of inductor and switch, a switch alone, a diode alone, and a combination of a switch and a diode. Another alternative reported in the literature is based on voltage multipliers [7,8,9]. The difference between these two methods is that voltage multipliers do not modify the topology, allowing voltage multipliers to stack up energy and increase the gain through the number of multiplier cells. In [10], some voltage-boosting techniques for PV microinverters were presented. These techniques used switched inductors and capacitors and/or transformers among switches and diodes to create step-up cells. The main drawback of the above methods is the increase in converter volume. Most of the topologies of the previously mentioned techniques are derived with an input inductor, which requires a large inductance to reduce the input current ripple (ICR) of the converter.
On the other hand, several topologies can achieve a high step-up gain using coupled inductors, which transfer energy from one winding to the other through a common core [11]. In [12], a high voltage level without an extreme duty cycle was obtained; however, these types of boost converter topologies operate with a large ICR. To minimize the current ripple, an input current unit based on a coupled inductor and an auxiliary LC circuit was used [13]. The inductor size is another challenge; therefore, interleaved converters are proposed to eliminate the ICR in certain duty cycles that depend on the number of phases. In [14], a floating interleaved boost with different duty cycles for each phase was presented. The ICR was successfully canceled with a linear dependence of inductance and a duty cycle; however, this condition is restricted to the vicinity of the selected operating point, which is the disadvantage of this technique. This problem may be solved by using a ripple cancellation network based on a tapped inductor [15]. In this case, the input current ripple is removed in all power ranges, but the current stress and power loss are also significantly increased. Switch devices must switch under hard switching conditions, causing voltage and current stress. To address this disadvantage, an auxiliary resonant circuit has been proposed. In [16], an interleaved boost converter with soft switching was presented for electric vehicle applications. The resonance circuit enabled zero-voltage switching for switches and diodes.
Recent research has presented a study of ICR elimination using a variable inductor (VI) [17,18]. The VI is a magnetic device that allows for variation in the inductance based on the current source; therefore, an auxiliary winding is needed [19]. In [20], a detailed design methodology and the possibility of reducing core volume in a power converter were presented. The main advantage of the VI is that only one magnetic component is used to simultaneously achieve power transfer and current ripple manipulation. Moreover, there is galvanic isolation between the power converter and the VI control circuit.
Parameter mismatch is inherent in a real physical system; therefore, the controller design must guarantee operation under real circumstances. The classical control techniques are not completely effective under the influence of model uncertainty. In [21], a robust controller was designed by employing Kharitonov’s theorem and considering the parameter variations in a DC–DC converter. A simple controller such as a PI can turn into a robust controller through the correct selection of its parameters. The only disadvantage of the method mentioned above is that the reduction in the output impedance in a nonminimum phase converter is achieved at the expense of the phase margin reduction. To solve the right-half zero problems, model reference adaptive control was incorporated into a conventional classic controller [22]. On the other hand, the robust control of DC–DC converters using the control theory has not been fully introduced. This control theory addresses the parameter uncertainty with some fictitious weighting functions added to the nominal model [23,24]. The most difficult task in this approach is the choice of the weighting functions. Moreover, the main advantage of this method is the possibility of guaranteeing some level of performance of the controlled system.
This paper presents a high-voltage-gain DC–DC boost converter with zero-ripple input current using a VI. The primary function of the VI is to regulate the current ripple in one of the inductors to achieve a proportional mirror current, resulting in the total elimination of ICR independent of the operating point. The present study proposes an accurate reduced-order dynamical model that considers the effect of switched capacitor dynamics. The output voltage controller is based on the control approach to deal with inductance variation and external disturbances. The main advantages of this proposal compared with other topologies reported in the literature are that a small inductor is required, the output voltage is not floated and grounded to the input voltage, the current ripple cancelation is independent of the operating point, and the system offers ripple elimination even in a transitory state. The proposed converter is very convenient for low-voltage sources such as batteries, PV, and fuel cell systems, which require high-voltage conversion capability and low-volume topology.
This paper is organized as follows: In Section 2, the operation principle and topology are explained, considering the effects of the VI. Section 3 introduces the analysis and selection of components, including voltage gain, inductor sizing, and capacitor sizing. The nonlinear model, linearized model, and control scheme of the proposed converter are provided in Section 4. Experimental results and the corresponding analysis are described in Section 5. Finally, the paper’s conclusion is given in Section 6.
2. Proposed Converter Topology
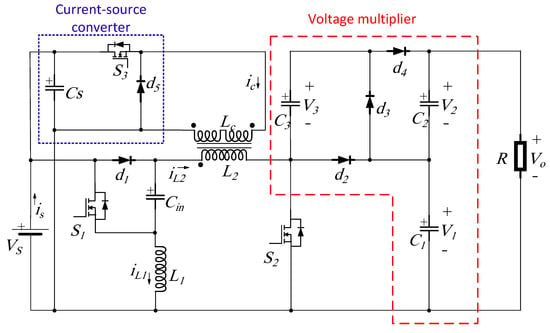
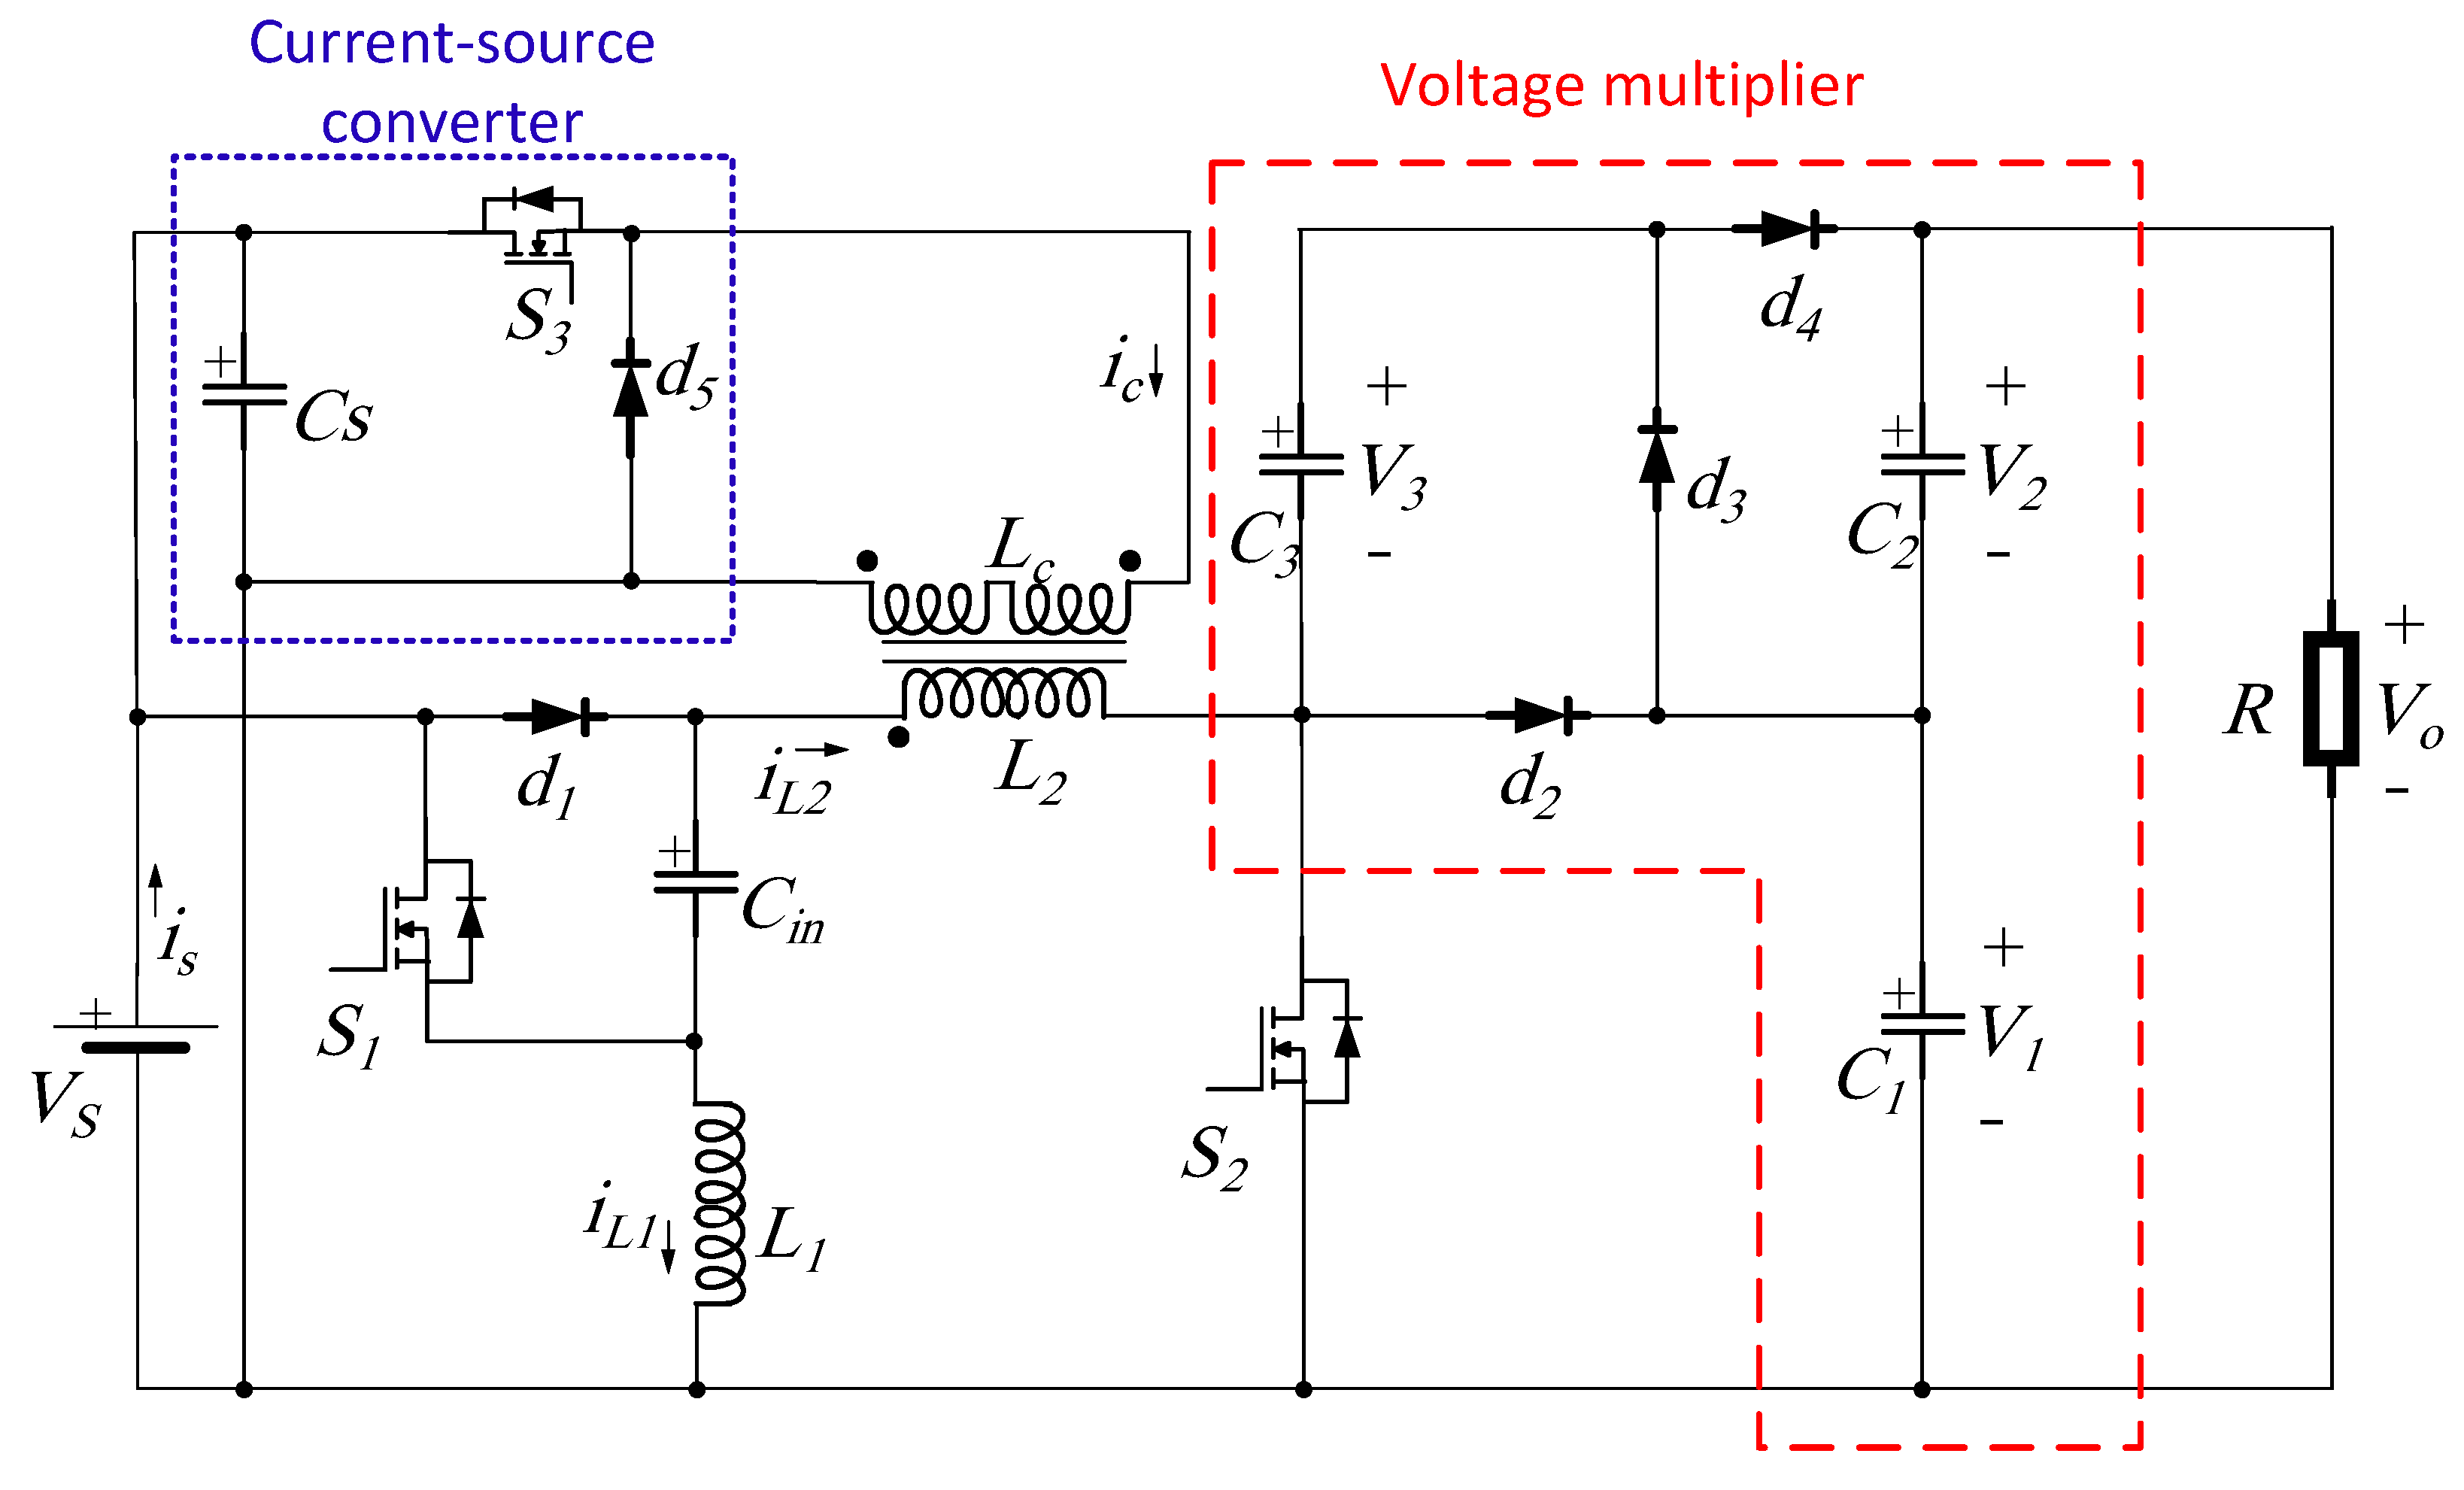
Figure 1 shows the circuit configuration of the proposed converter. To minimize the ICR, switches and operate complementarily. The input current is the sum of inductor currents and , similar to interleaved converters. The voltage gain across the capacitor is equivalent to the voltage gain in the traditional boost converter. The voltage multiplier improves the voltage gain and reduces the voltage stress on the switching components. In this case, the output voltage is the sum of and . The inductor can be modified to reach a wide operating range with a zero-ripple input current. The current-source converter is incorporated to control the VI (). This converter has a pulsating input current; however, a small input capacitor filters this current and therefore becomes negligible.
Figure 1.
The schematic diagram of the proposed converter and its power stages.
2.1. Analysis of the Operating Principle
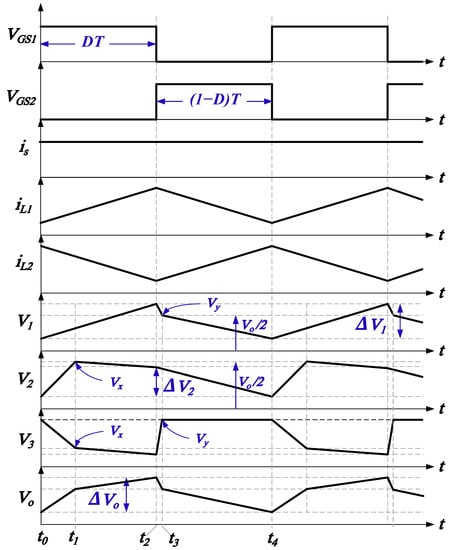
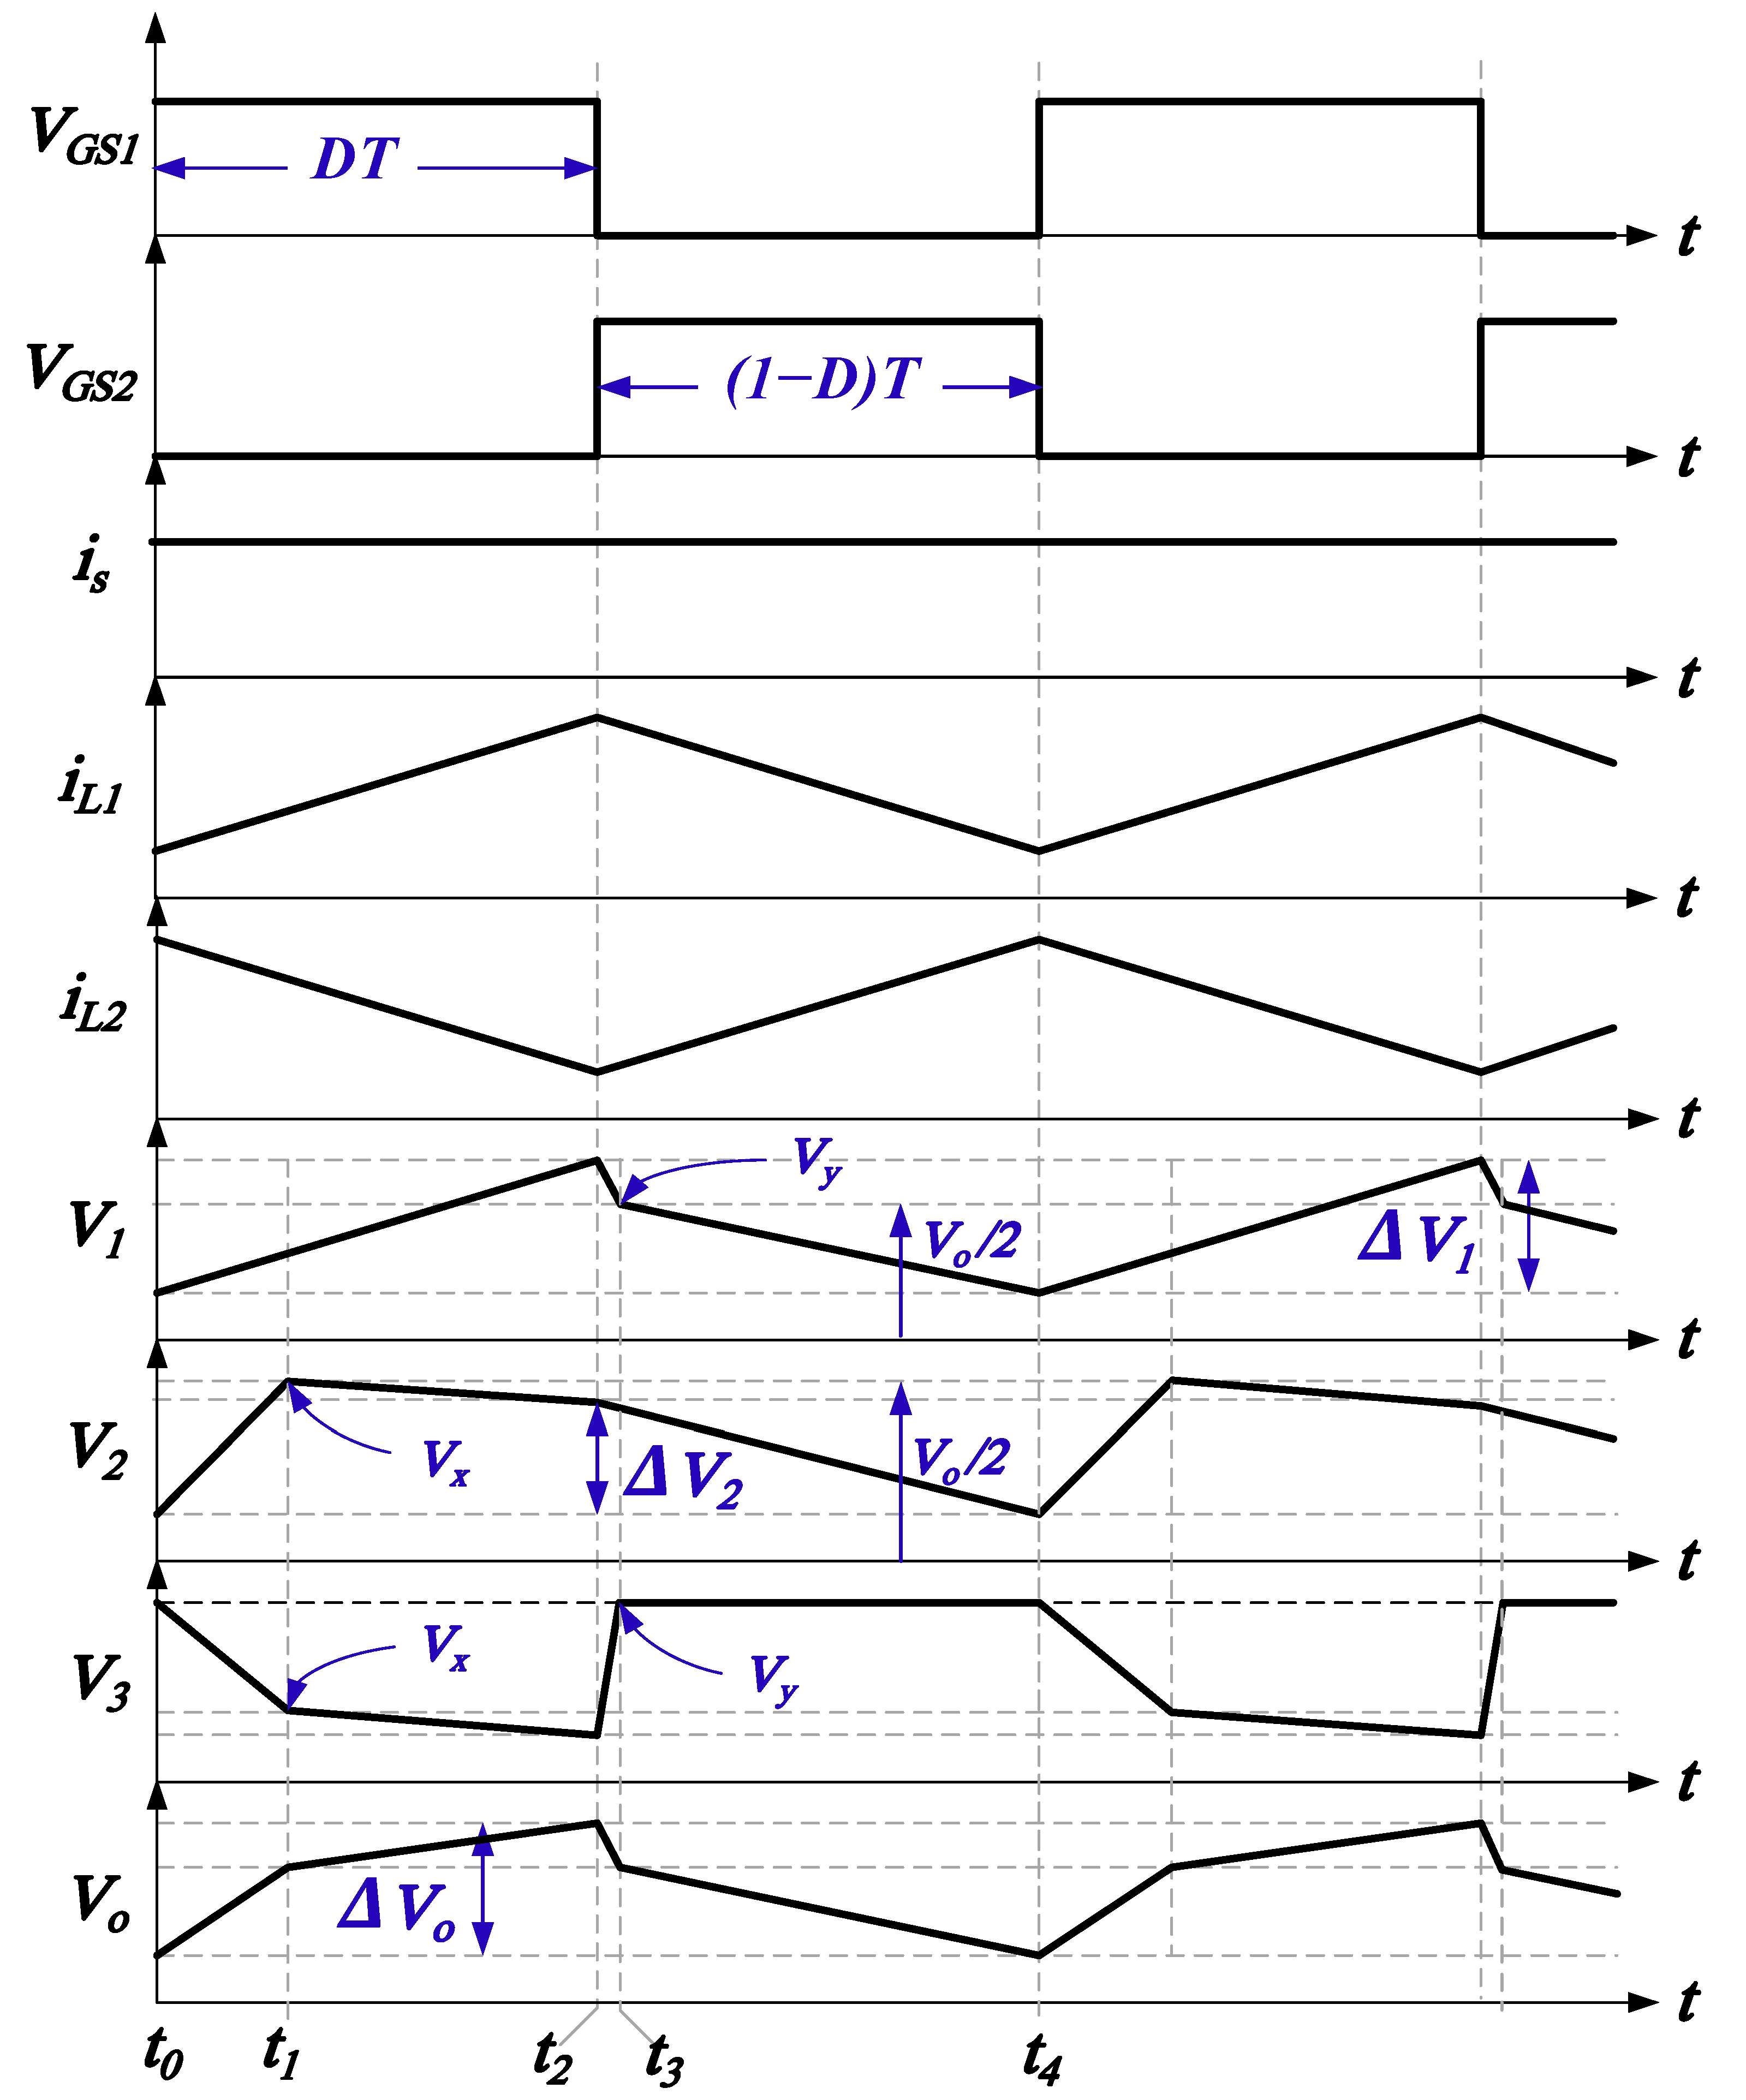
The related waveforms of the main converter, in steady-state operation, are shown in Figure 2.
Figure 2.
Steady-state waveforms of the main converter.
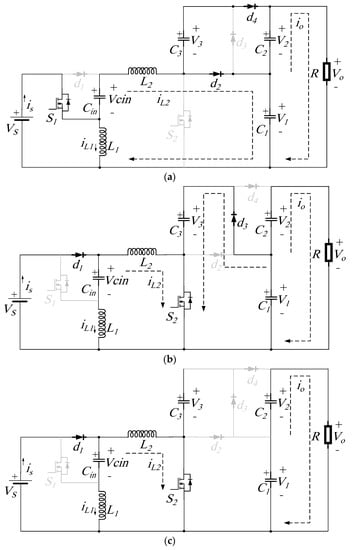
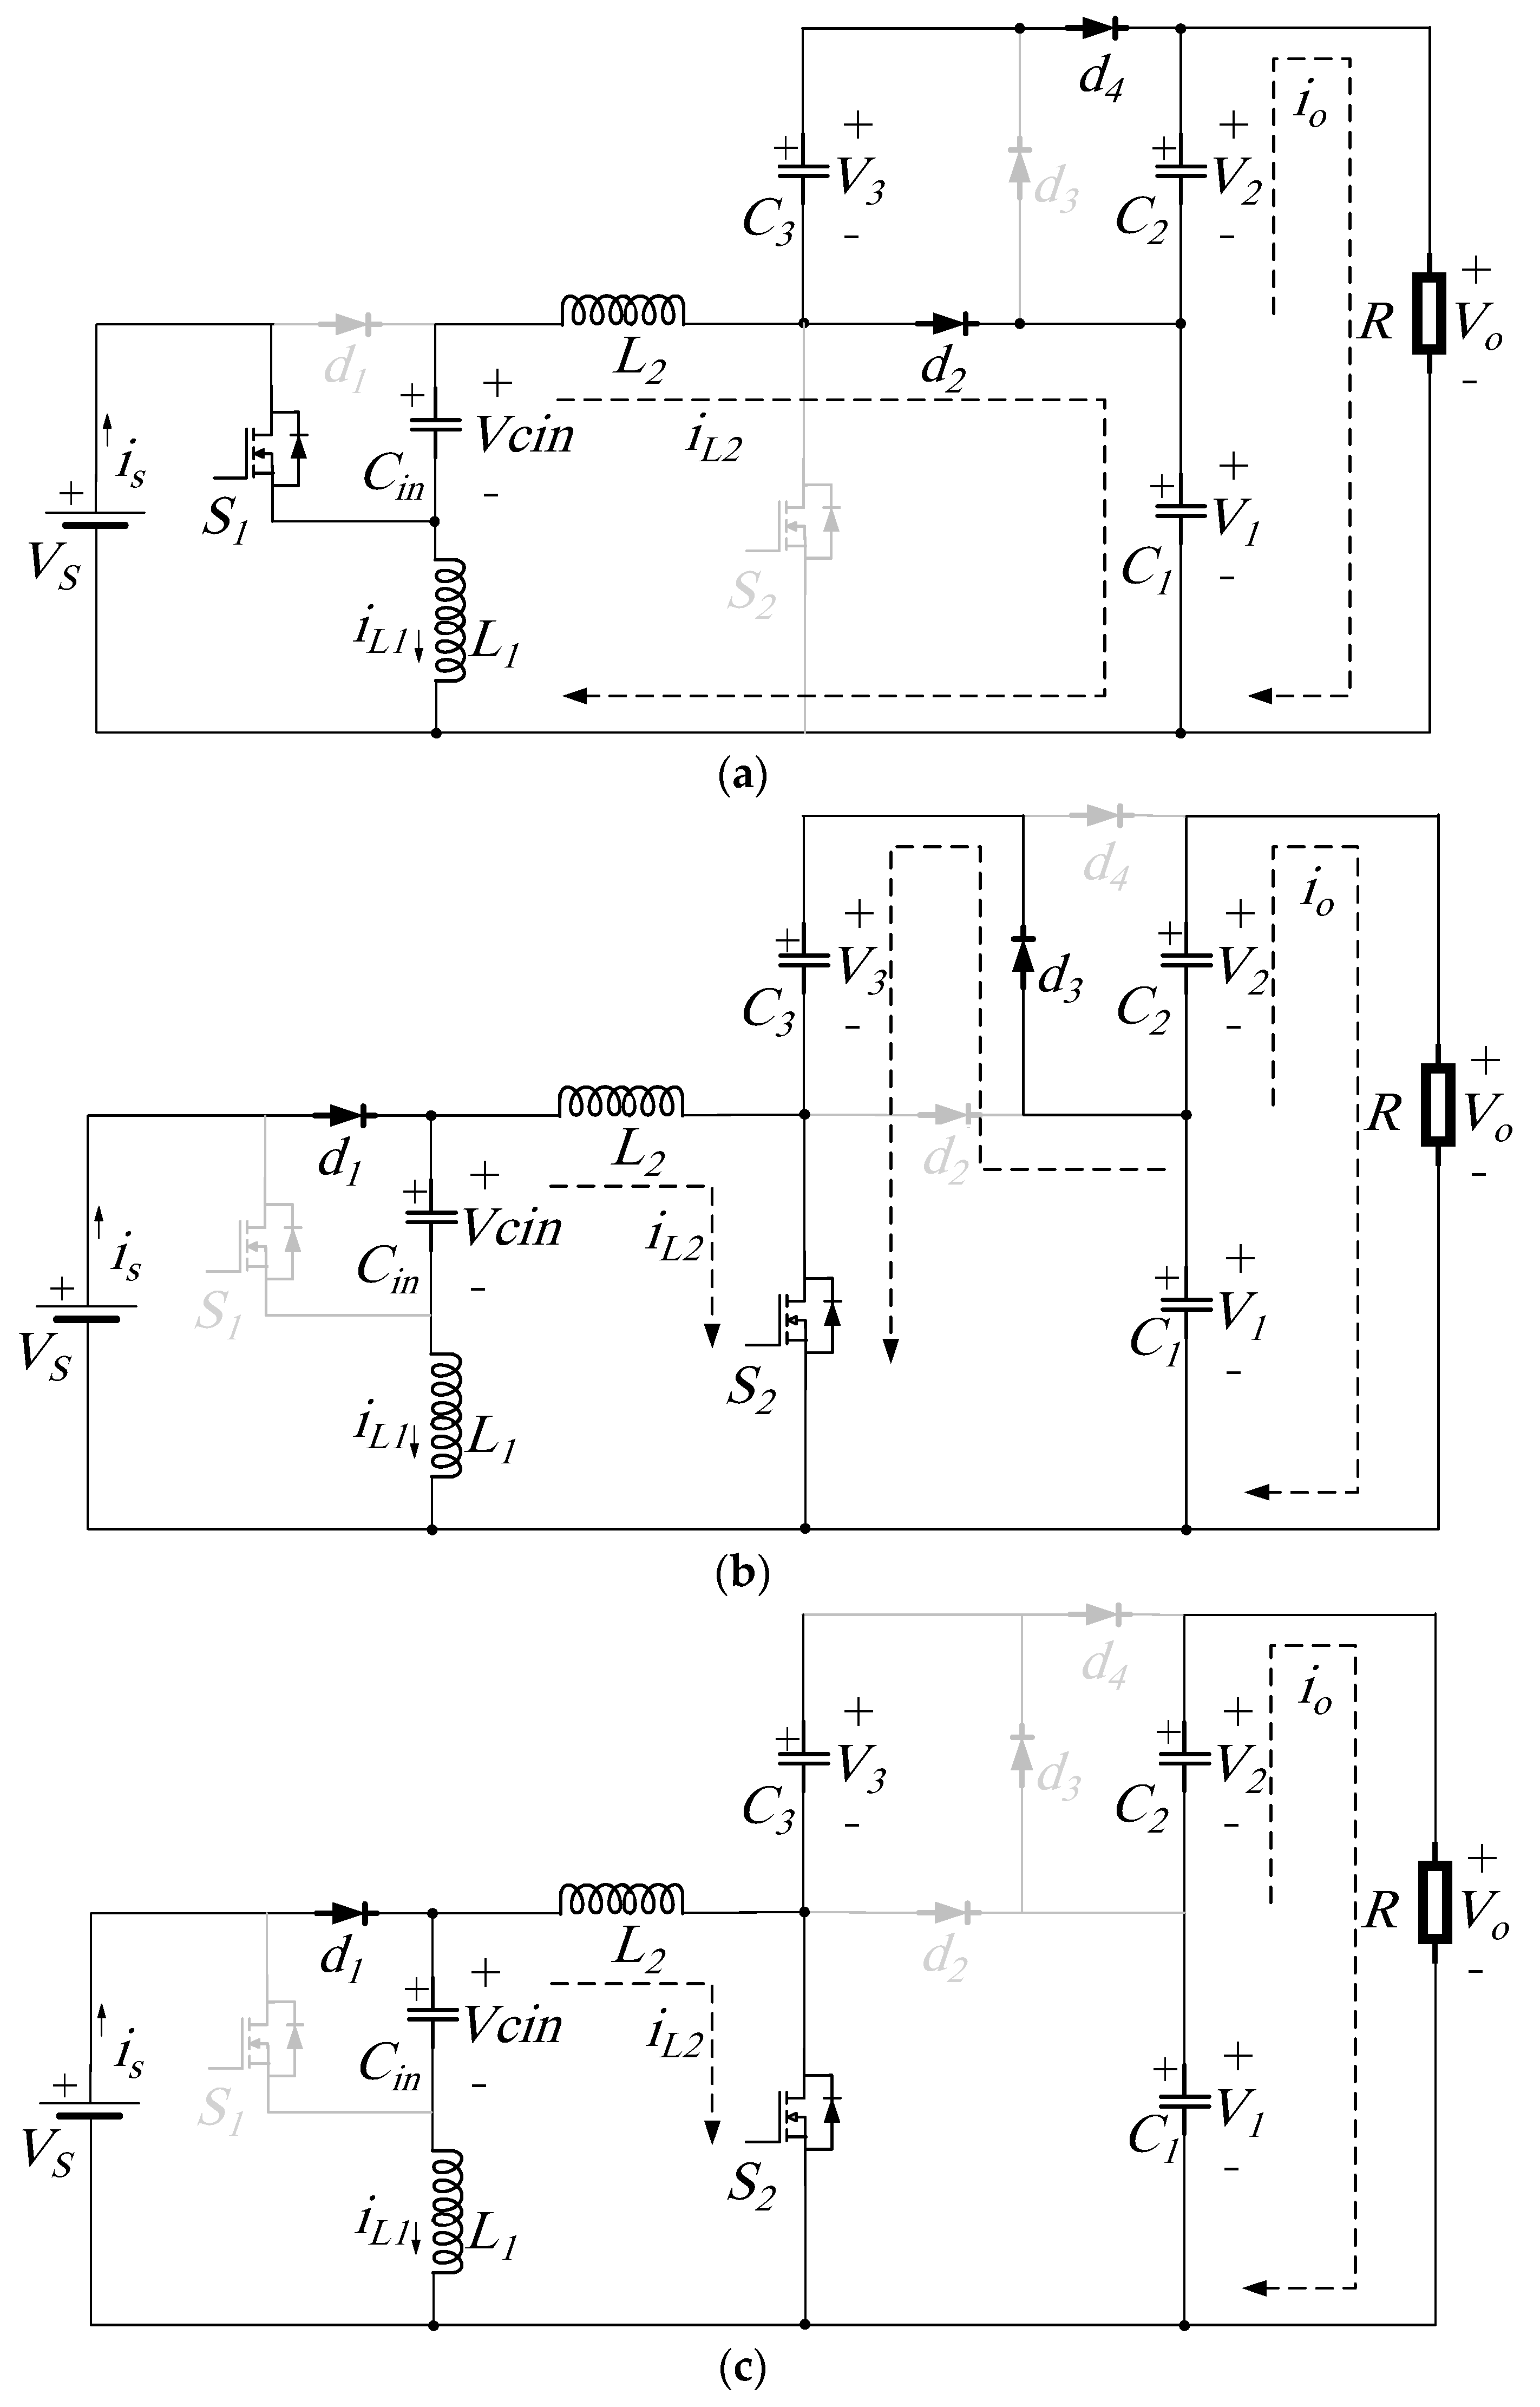
Mode I [, ]: During this time, the power switch is turned on, is turned off, and and are forward-biased. The equivalent circuit is depicted in Figure 3a. In this case, the input voltage charges the inductor , and the capacitor and inductor are discharged to feed the capacitor and the load. In addition, the capacitors and are connected in parallel to deliver energy to the load. From to , the charge of capacitors and starts to balance. From to , the charge of capacitors and is balanced. The voltage level of both capacitors is equal to . The voltage level of is approximately equal to . When is equal to , this operational mode is finished.
Figure 3.
Operating modes during a switching period: (a) Mode I; (b) Mode II; (c) Mode III.
Mode II [, ]: During this time, the power switch is turned off, is turned on, and and are forward-biased. The equivalent circuit is depicted in Figure 3b. In this case, is being discharged to feed capacitor . The input voltage charges the inductor . Capacitor is connected in parallel with . The voltage level of both capacitors is equal to . The voltage level of is approximately equal to . Additionally, capacitors and deliver energy to the load. When is equal to , this operational mode is finished.
Mode III [, ]: During this time, the power switch is turned off, is turned on, and is forward-biased. The equivalent circuit is depicted in Figure 3c. In this case, is discharged to feed capacitor . The input voltage charges the inductor . Capacitor is charged and isolated from the circuit. Capacitors and deliver energy to the load. When is equal to , this operational mode is finished.
2.2. Variable Inductor Operation
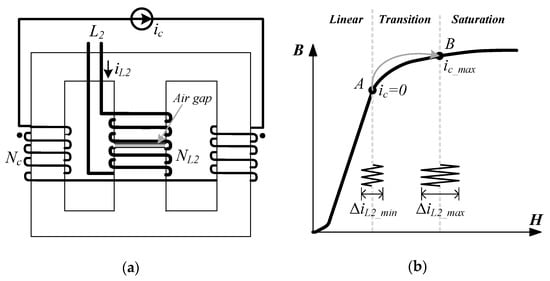
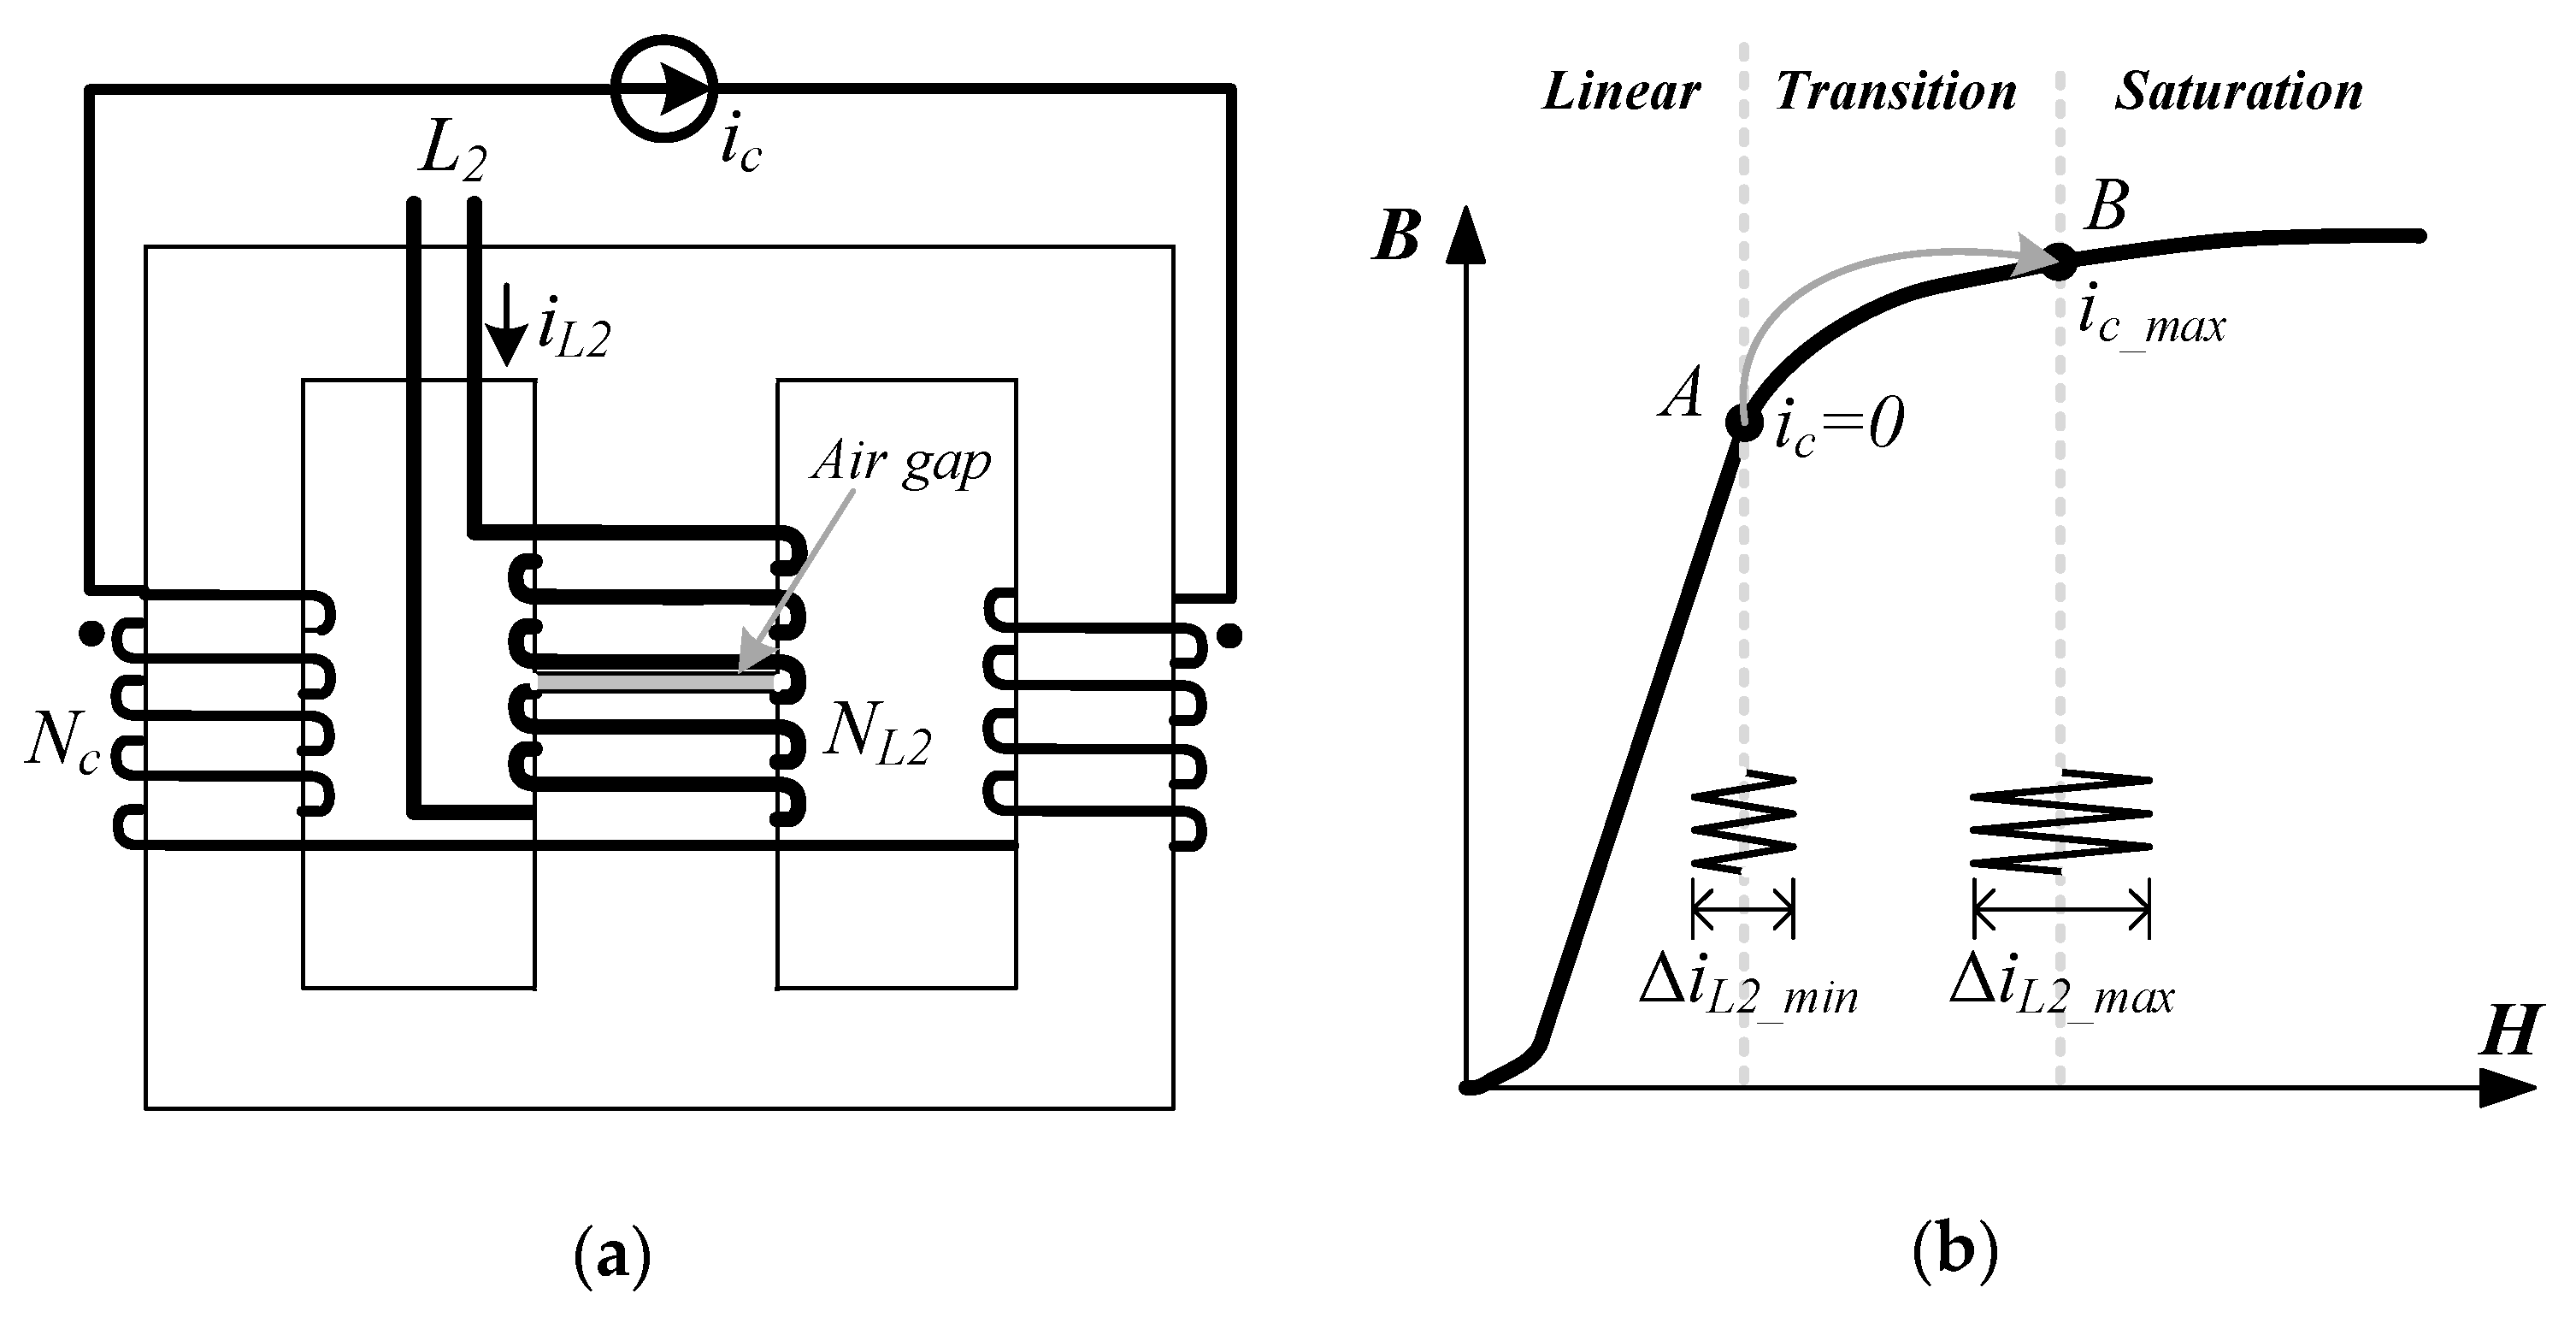
A VI is a current-controlled device. The VI is implemented on a double E-core, which contains an auxiliary winding in the outer arms and the main winding in the center arm, as shown in Figure 4a. The principle of operation is based on the variation in the main winding’s inductance through the flux control created by the auxiliary winding, as can be observed in Figure 4b. The amplitude variation in the current ripple is inversely proportional to the inductance of the power inductor. The primary function of the VI is to adjust the ripple in a linear relationship with the duty cycle.
Figure 4.
VI structure [18]: (a) winding distribution; (b) operating points on the B–H curve. Point A represents the limit of the linear region, and point B represents the limit of the transition region.
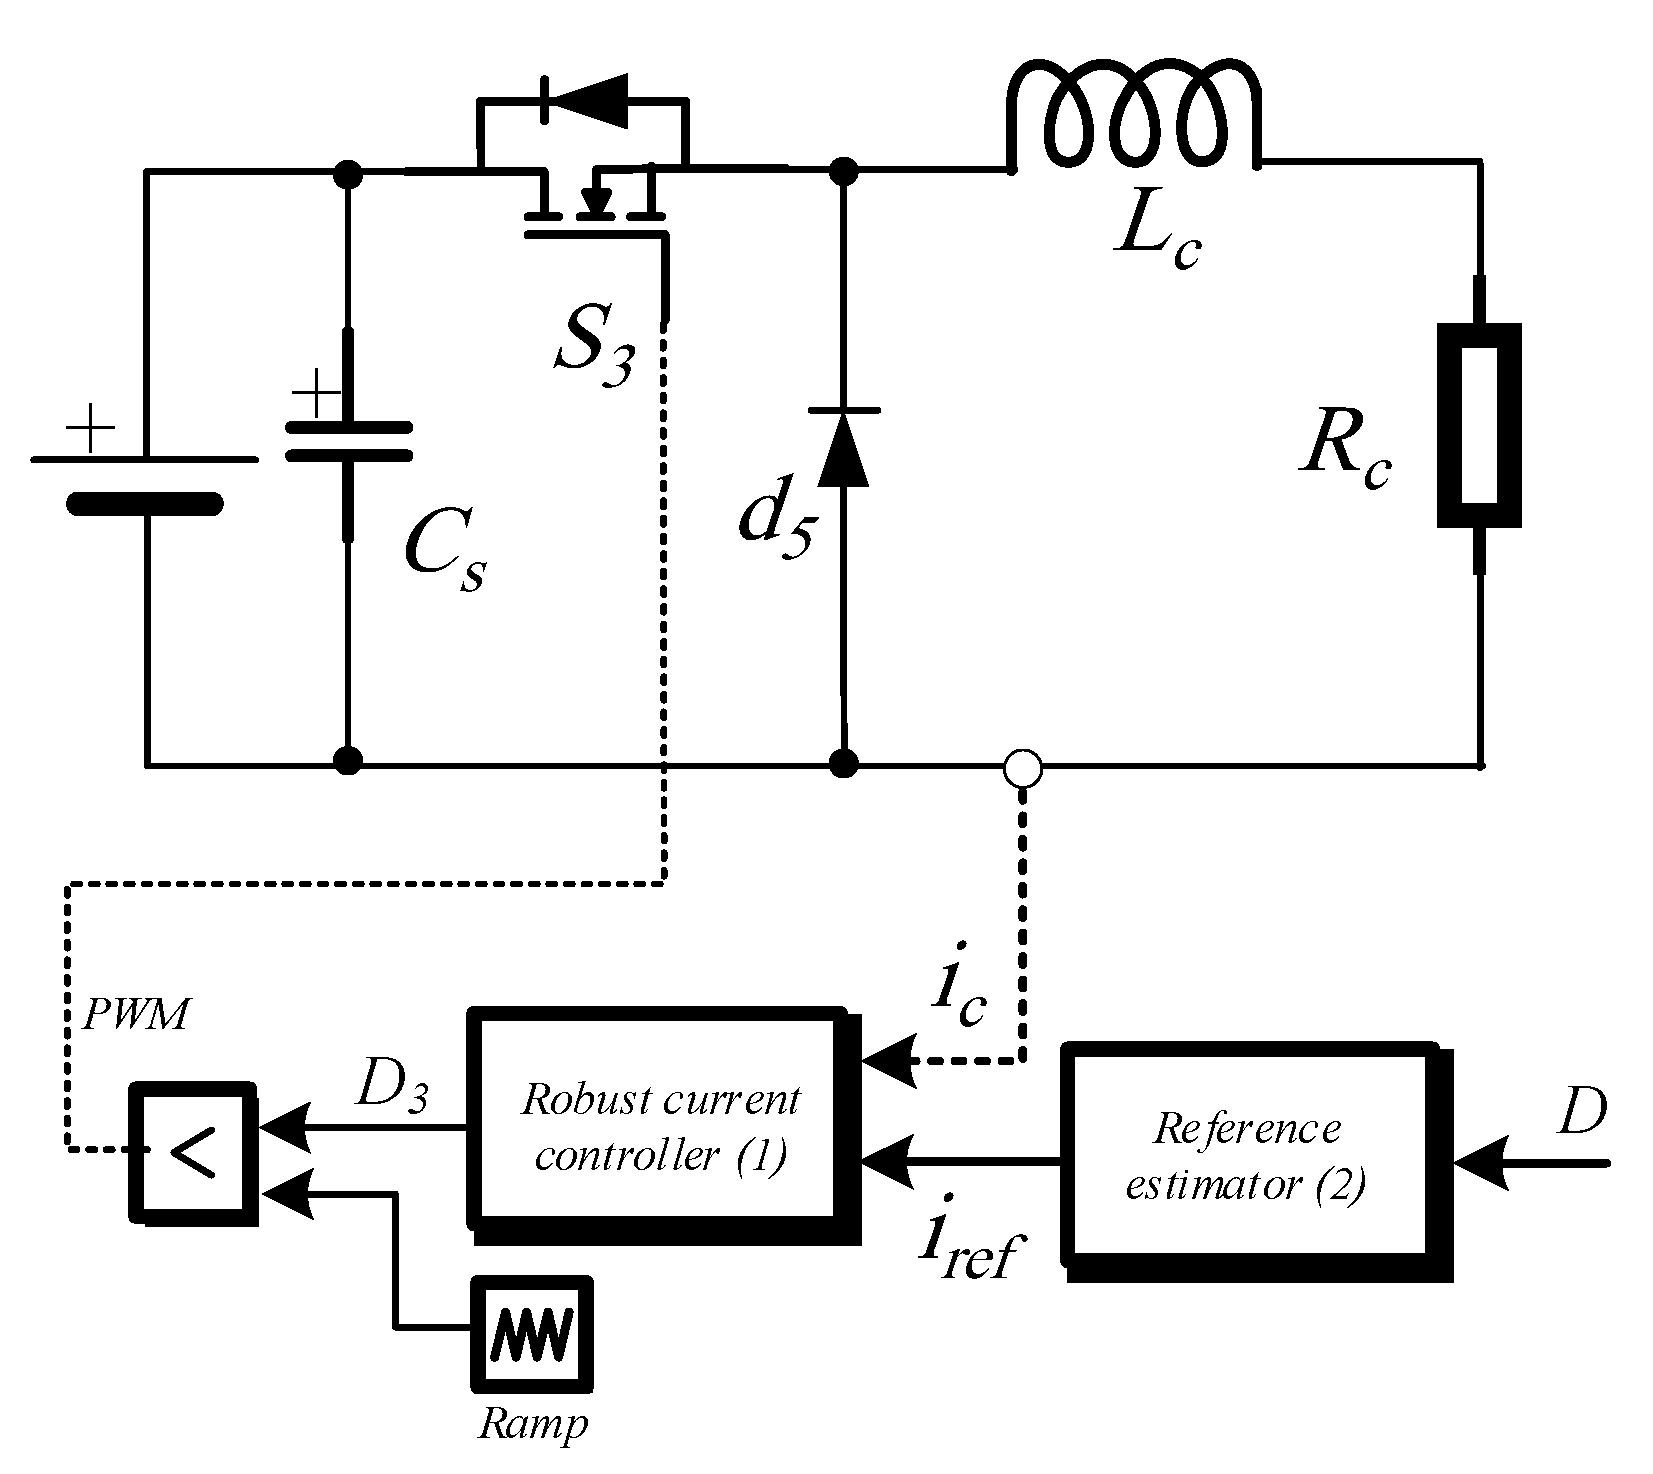
The controlled current in the auxiliary winding modifies the magnetic flux density of the core and moves the operating point. The current-source converter regulates the inductance using a robust controller since the VI suffers from uncertainties and external perturbations. However, the relationship between controlled current and inductance is nonlinear [20]. A reference estimator relates the controlled current and to solve the nonlinear relationship. The estimator works over a specified span in the operating region where the VI has a quasilinear behavior. Figure 5 presents a schematic diagram for the practical implementation of the VI control. Details of the control design and implementation are in [18].
Figure 5.
Schematic diagram of the power stage for the VI.
As it has been mentioned before, a robust controller is needed to regulate , and the control input is expressed as [18]:
where and are the inductance and resistance of the auxiliary inductor, respectively; is a controller gain; is the controlled current; is the voltage source; is the current error; and is the control input.
The current reference estimator can be determined as follows [18]:
where is the change in the value of , is the change in the value of , is the duty cycle of the proposed boost converter, and is the minimum control current.
3. Analysis and Selection of Components
3.1. Voltage Gain
Under the assumption that the equivalent series resistance (ESR) is negligible, and by applying Kirchhoff’s voltage law in the equivalent circuit of Mode I (Figure 3a), the following equations are obtained:
where is the voltage across , is the voltage across , and is the voltage across .
The following equations can be derived by using the volt–second balance principle for both inductors:
By solving (7), the voltage across can be obtained as follows:
By using (8) and (9), and considering output voltage , the proposed converter gain can be expressed as follows:
In a practical implementation, the ESR of inductors limits this gain. The next equations consider this limitation.
where , , , and are the currents and ESR of and , respectively.
By applying Kirchhoff’s current law in the equivalent circuit of Mode I, the following equations can be written:
where is the current of , is the current of , and is the current load; in addition, is assumed to be equal to .
The current equations of Mode II are calculated as follows:
By applying the charge–second balance to and , the following equations can be obtained as follows:
By solving simultaneously (11), (12), (17) and (18), the practical converter gain is expressed as follows:
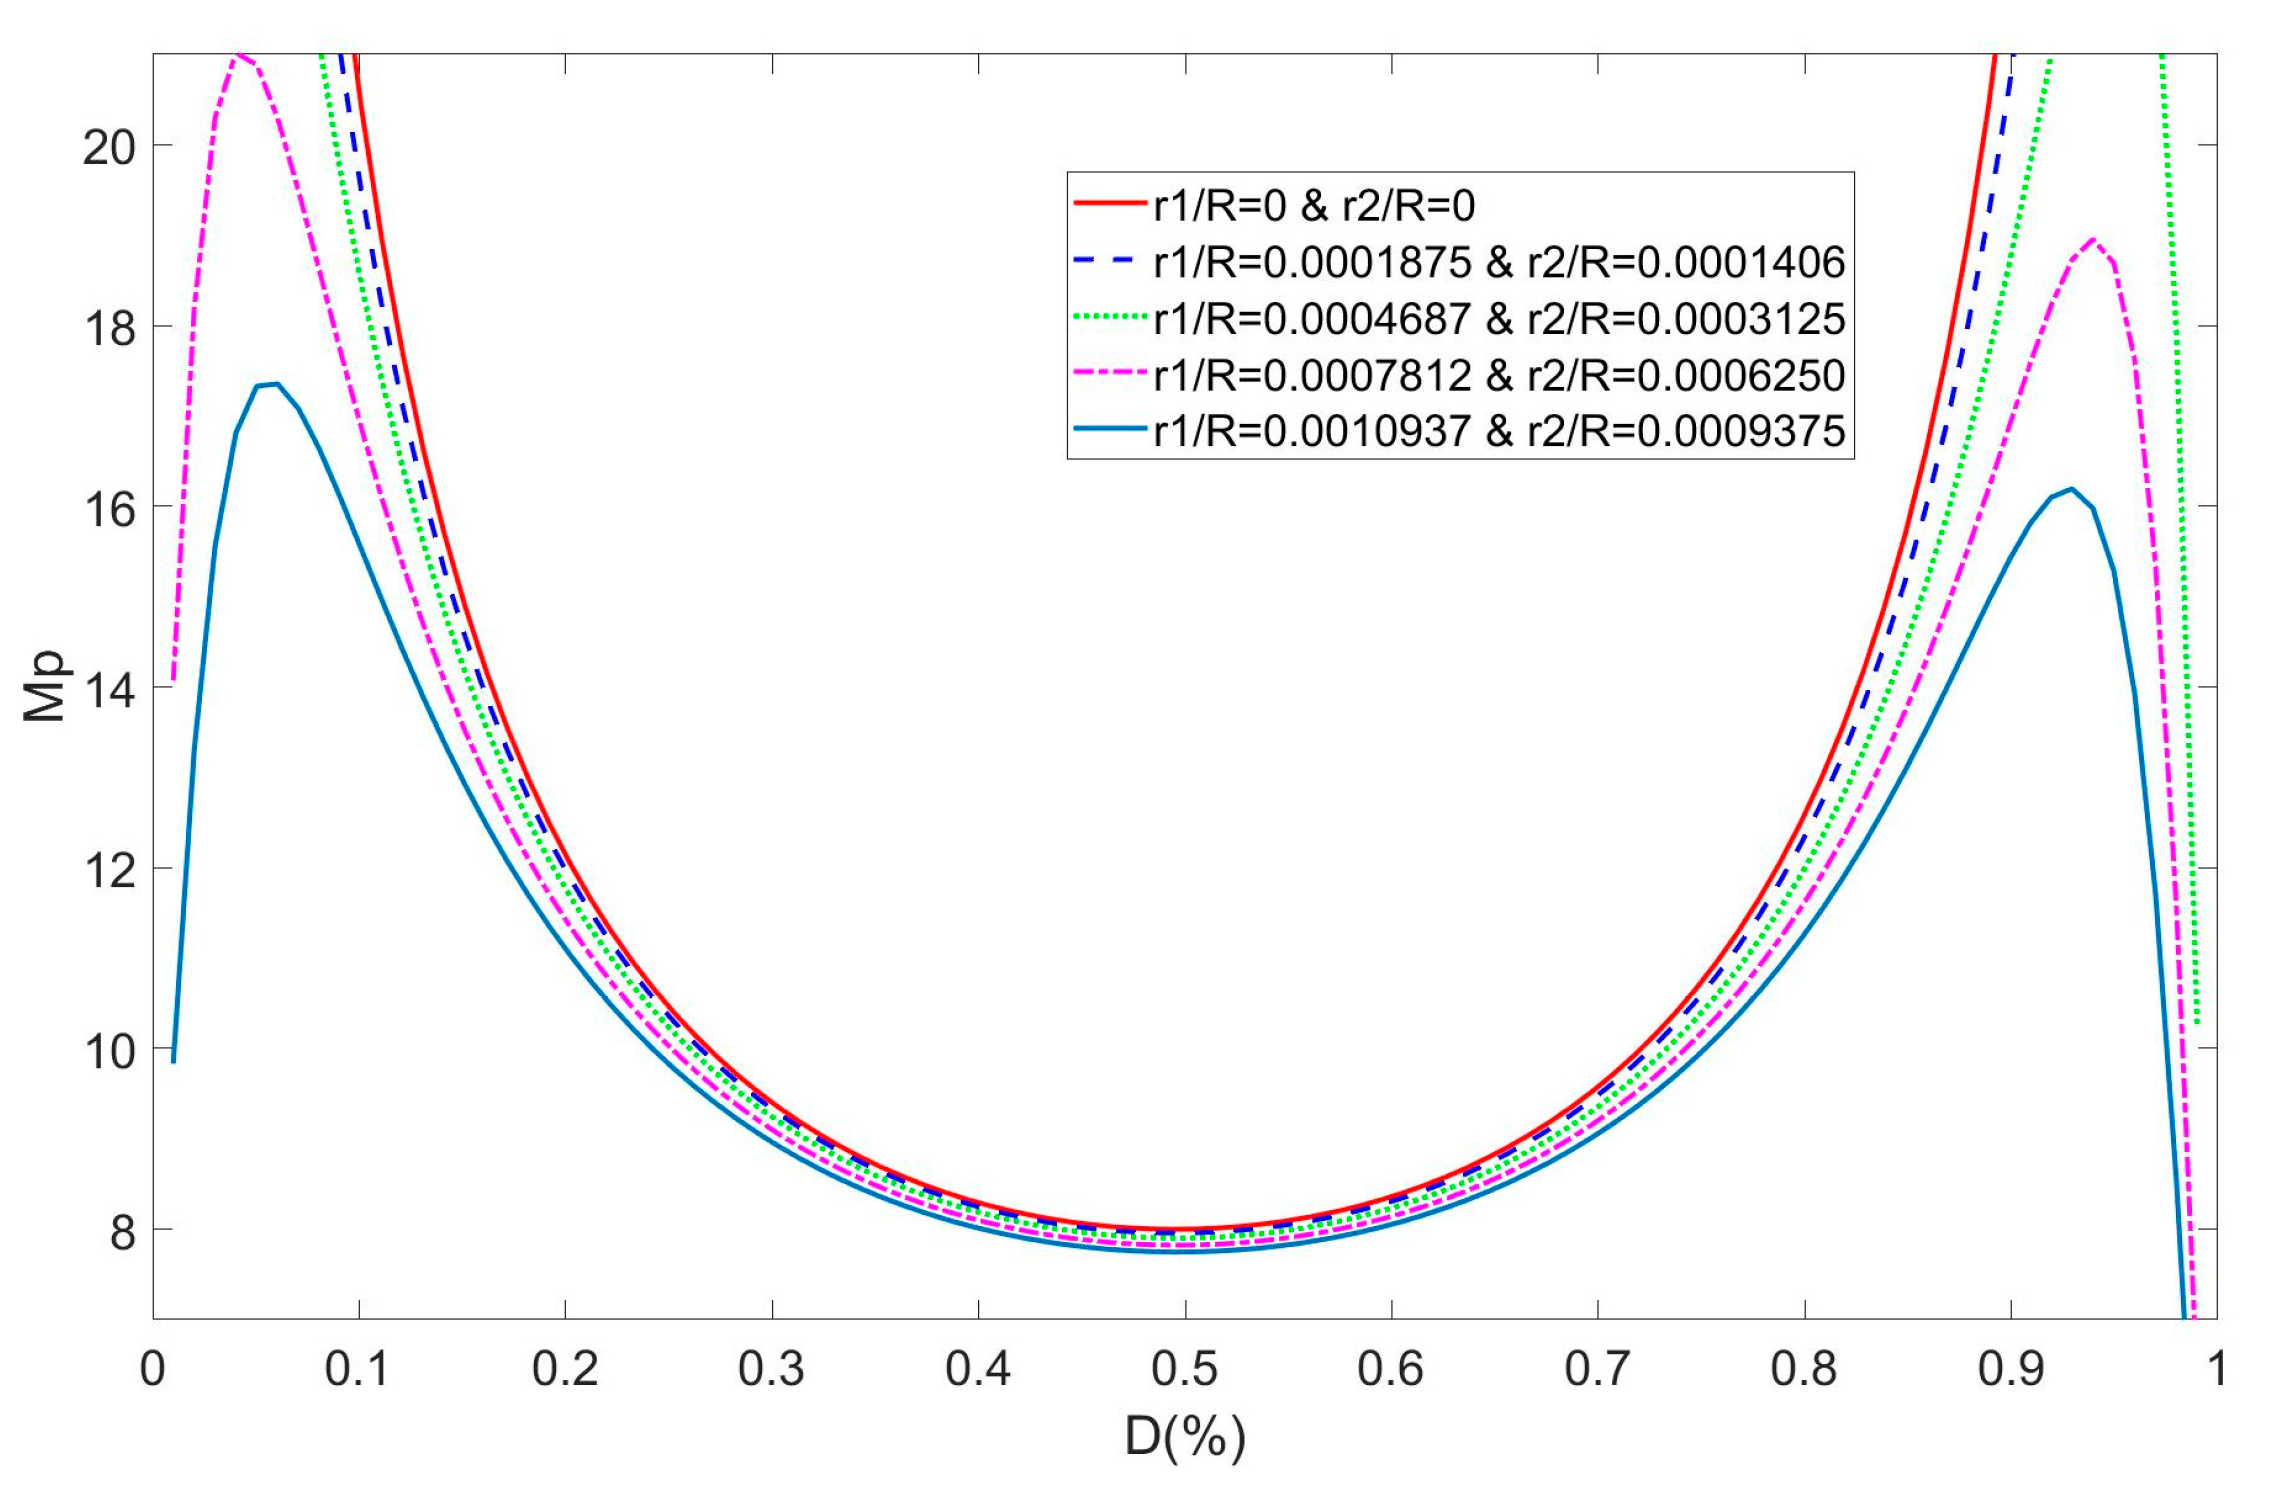
Figure 6 shows the practical converter gain under the effect of different ratios of load resistance , , and . As can be seen, the minimum voltage gain is eight and occurs at D = 50%, when the ESR is negligible. The gain increases if the duty cycle is different than 50%.
Figure 6.
Voltage gain versus duty cycle considering ESR of inductors.
3.2. Inductor Sizing
By using (17) and (18), the average current of inductors and can be calculated as follows:
To eliminate the ICR, the sum of both inductor current ripples must be zero, considering (3) and (6) and their period yields
After some elementary algebraic transformations, Equation (22) yields
As can be seen, inductors present a linear dependence. Therefore, this condition can be used to calculate the minimum inductance for in critical conduction mode. The minimum inductor current for is determined by using (21) and the change in current. This yields
Setting to zero and substituting (24) into (23), the minimum inductance is
Considering as the switching frequency, the obtained value in (23) is the maximum for the VI, i.e., the minimum inductance for the VI must be fulfilled.
3.3. Capacitor Sizing
In the study of power converters that use capacitor voltage multipliers, it is rare to present the relationship between capacitance and output voltage ripple. As can be observed in Figure 2, a good approximation is
where is the voltage change in , is the voltage change in at = , and is the output voltage ripple.
The change in the charge in can be calculated as follows:
Assuming capacitors , , and are equal, and is the capacitance, solving (28) yields
Additionally, the change in the charge in can be calculated as follows:
By solving (30), we have
Finally, substituting (29) and (31) in (27), the capacitance of the voltage multiplier in terms of output voltage ripple is
4. Dynamic Analysis and Control Scheme
4.1. Switched Converter Model
The modeling of DC–DC converters with voltage multipliers involves several challenges. The dynamic of switched capacitors cannot be modeled using the averaging method [25]. A precise reduced-order model solves this problem. The complexity of the model depends on the states of . The main objective of is to transfer energy from to . However, this energy transfer occurs suddenly in Mode I. Figure 3a presents the dynamics of Mode I. A set of equations can be obtained as follows:
Figure 3b,c present the dynamics of Modes II and III. These modes are modeled by using the following equations:
where is the equivalent resistance inducing losses due to the energy transfer among capacitors.
Considering (33)–(42), the switched model of the converter is as follows:
where is the switching function.
Current is denoted as , current is denoted as , voltage is denoted as , voltage is denoted as , voltage is denoted as , and the sum of and is the output of the system . The next expression represents the reduced-order nonlinear model:
where
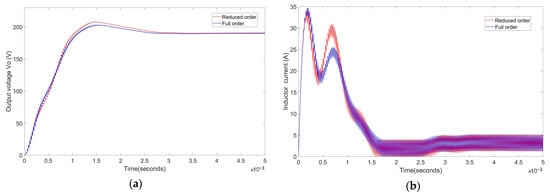
Figure 7 shows the comparison between the full-order model and the reduced-order model. As can be observed, the steady-state and dynamic response in the simulation present good agreement.
Figure 7.
Comparison between the reduced-order model and the full-order model: (a) output voltage; (b) current of .
The simulation of the full-order model was carried out using PSIM software, while the simulation of the reduced-order model was performed using MATLAB software. The backward Euler method and 10 ns time step were used to solve Equation (48). The parameters involved in this simulation were = 24 V, = 90 μH, = 60 μH, = 100 μF, = = = = 47 μF, = 100 mΩ, = 25 mΩ, = 20 mΩ, = 200 Ω, and (average) = 0.6. In the case of , the value is strongly influenced by the ON-state resistance of transistor and the ON-state of diode .
4.2. Linearized Average Model
The linear state–space model can be linearized from (48) and by replacing the switching function with its average value . Setting the relevant derivatives in (48) to zero, the desired operating values can be obtained as follows:
From Equation (48), the linearization of the average model around the desired equilibrium point yields the following state equations:
with , , , , , , , and , where the superscript (~) represents the linearized signal. The matrices , , and are obtained via the Taylor first-order development as follows:
The system matrix is given as follows:
While the input matrices are written as follows:
In the case of the output matrix,
The control voltage gain and audio susceptibility transfer functions corresponding to the state in Equation (50) are, respectively,
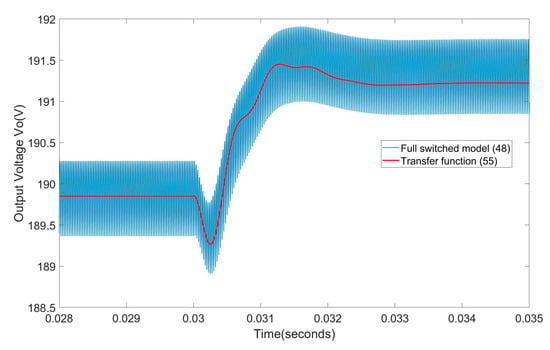
Figure 8 compares the switched model (48) and the output voltage transfer function (55) using the same parameters as in Figure 7. The input presents a step change of 1% at time = 0.03 s, and the output voltage changes from 189.6 to 191.2 V.
Figure 8.
Comparison between the fully switched model and the transfer function .
4.3. Control Design
The general philosophy of robust control is to design a controller for a set of models instead of designing for just one model. Compared with the physical system, the open-loop plant presents a plant-model mismatch. In this study, the uncertain model considers a multiplicative uncertainty.
The transfer function of the system in the presence of uncertainty can be expressed as follows:
where is the uncertain plant; is an uncertain weight, which captures the size of the deviation; and represents the unstructured uncertainty.
The deviation of and at some frequency is measured by the relative error of their frequency response, and the mathematical expression is given as follows:
The main uncertainties are caused by , , , and . The uncertainty radii are listed in Table 1.
Table 1.
Nominal values and uncertainty radii of the proposed converter.
Selecting weighting functions are essential in robust control design techniques. Low frequency requires a high disturbance rejection. The weighting function acts as a low-pass filter. Therefore, the following form of weighting function is selected [26]:
where is allowable bandwidth, is an allowable steady-state error, and is an allowable high-frequency error.
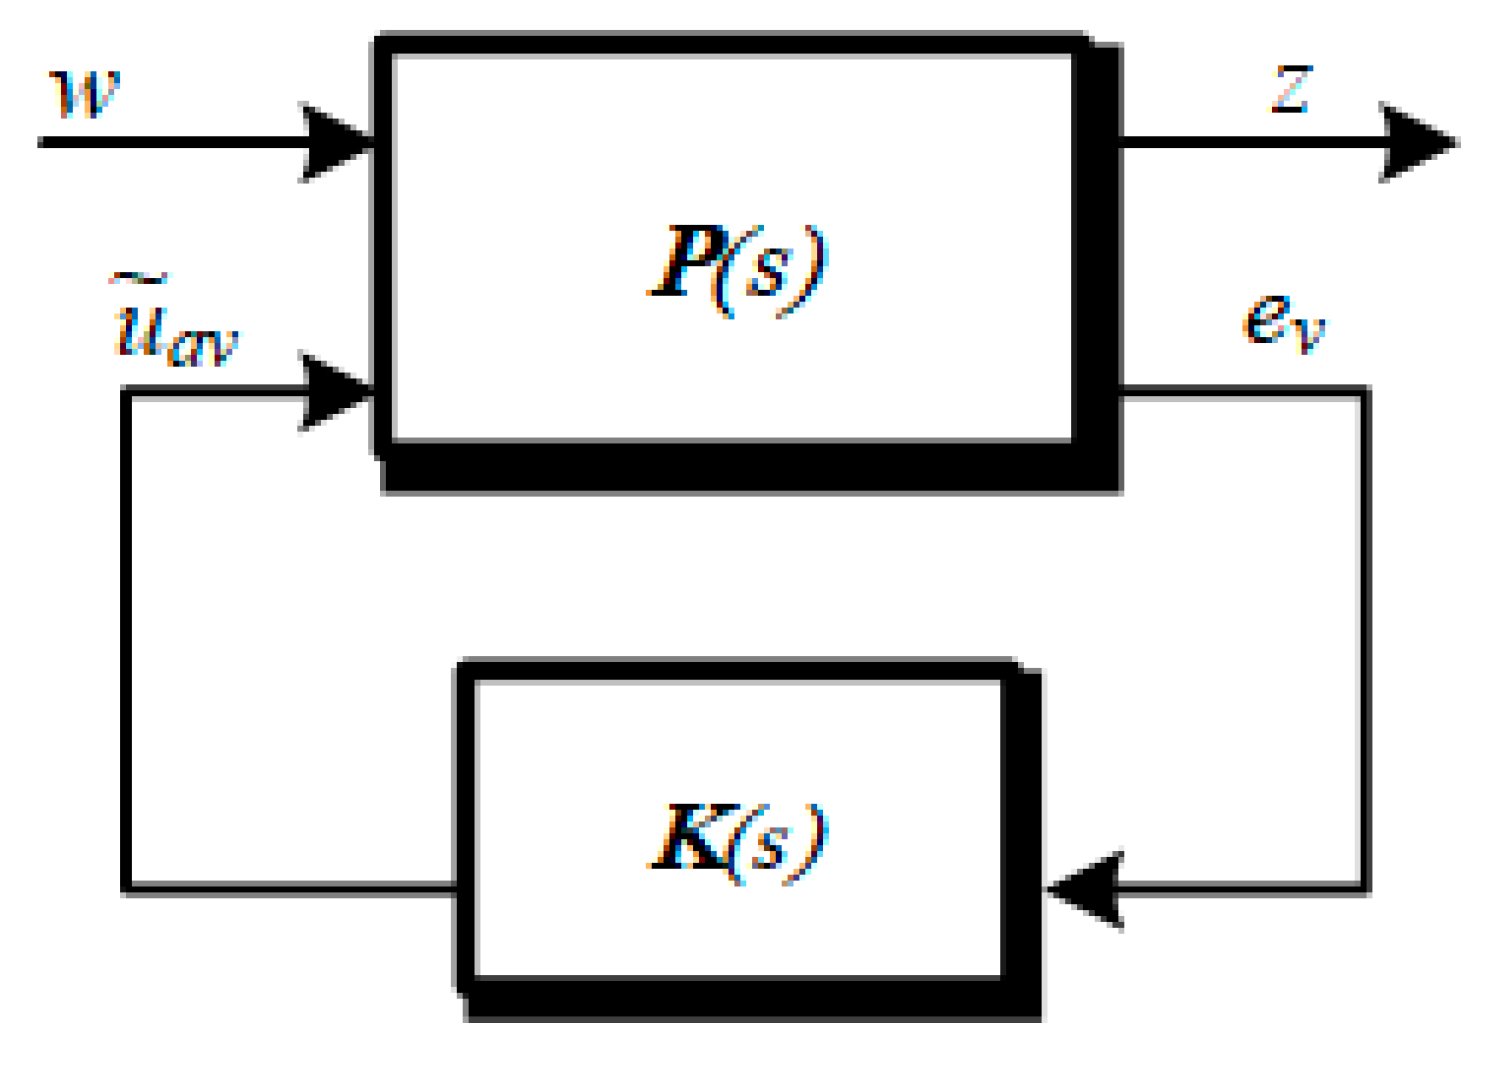
The process is presented according to the standard linear fractional transformation (LFT) configuration, as shown in Figure 9.
Figure 9.
Standard control problem.
The generalized plant has two inputs: the exogenous input , which includes the reference signal and disturbance, and the manipulated variable . There are two outputs: the error signal and the measured variable .
The closed-loop system can be expressed as follows:
where
Considering as a constant input weight and as a constant output weight, the lower LFT gives the system transfer function matrix from to as follows:
where
The control objective is to synthesize a stabilizing controller for all the plant models, i.e., control theory involves the minimization of the norm of . The infinity norm can be calculated using the following equation:
where is the maximum singular value, and the value of implies the disturbance rejection capability.
The output voltage controller is chosen as a proportional–integral controller as follows:
where is the proportional gain, and is the integral gain.
The controller parameters of (63) were obtained with the hinfstruct command of MATLAB. This command extends classical synthesis to fixed-structure linear control systems [27]. The selection of weighting functions is essential to define the desired performances of the closed-loop control system. Performance weight provides the steady-state error and settling time, using the bandwidth and term [28]. The control action weight must be adjusted according to the following criteria: A smooth control input is obtained if > 1, and aggressive control input is obtained if < 1. The effect of must be scaled to obtain a disturbance signal less than one in magnitude, using an input weight . Therefore, this term is inverse to static gain. The weighting functions are selected as follows:
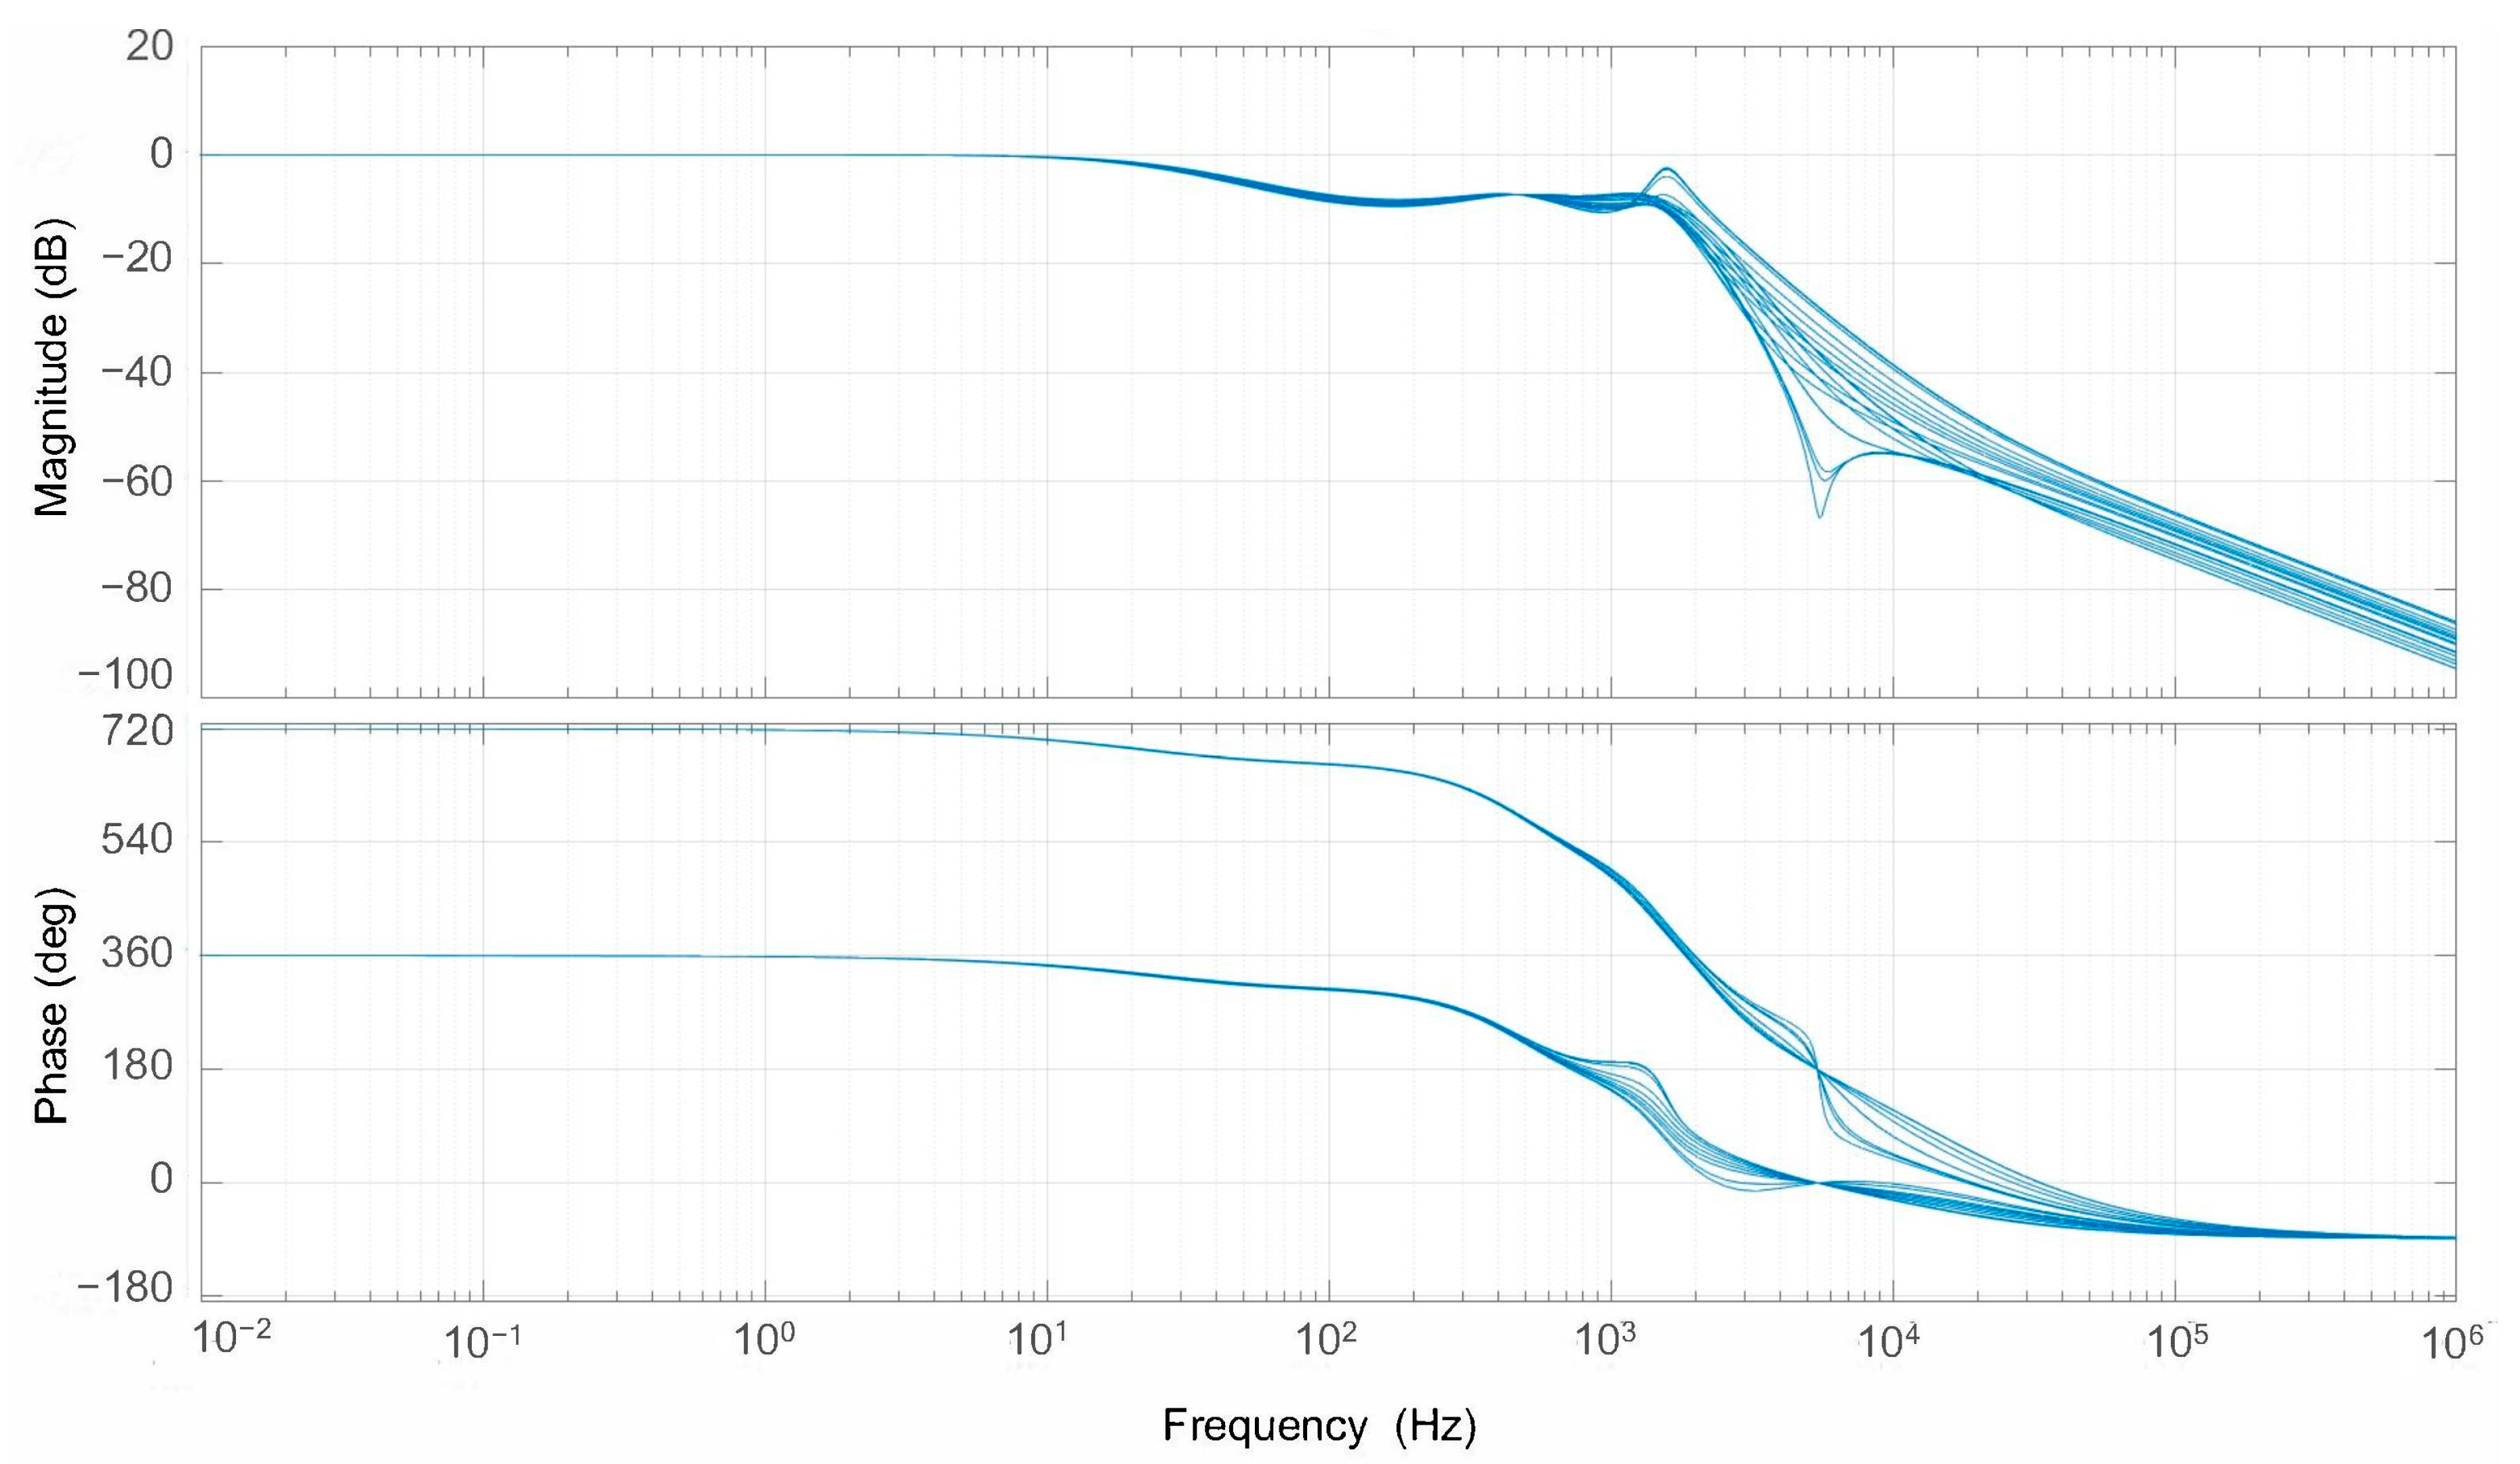
The obtained control gains are = 0.00251 and = 1.642, while the value achieved for the closed-loop system is 0.704. Figure 10 shows the behavior of the uncertain plant in a closed-loop system based on its corresponding bode diagram.
Figure 10.
Bode diagram of closed-loop response. From top to bottom: magnitude diagram (top) and phase diagram (bottom).
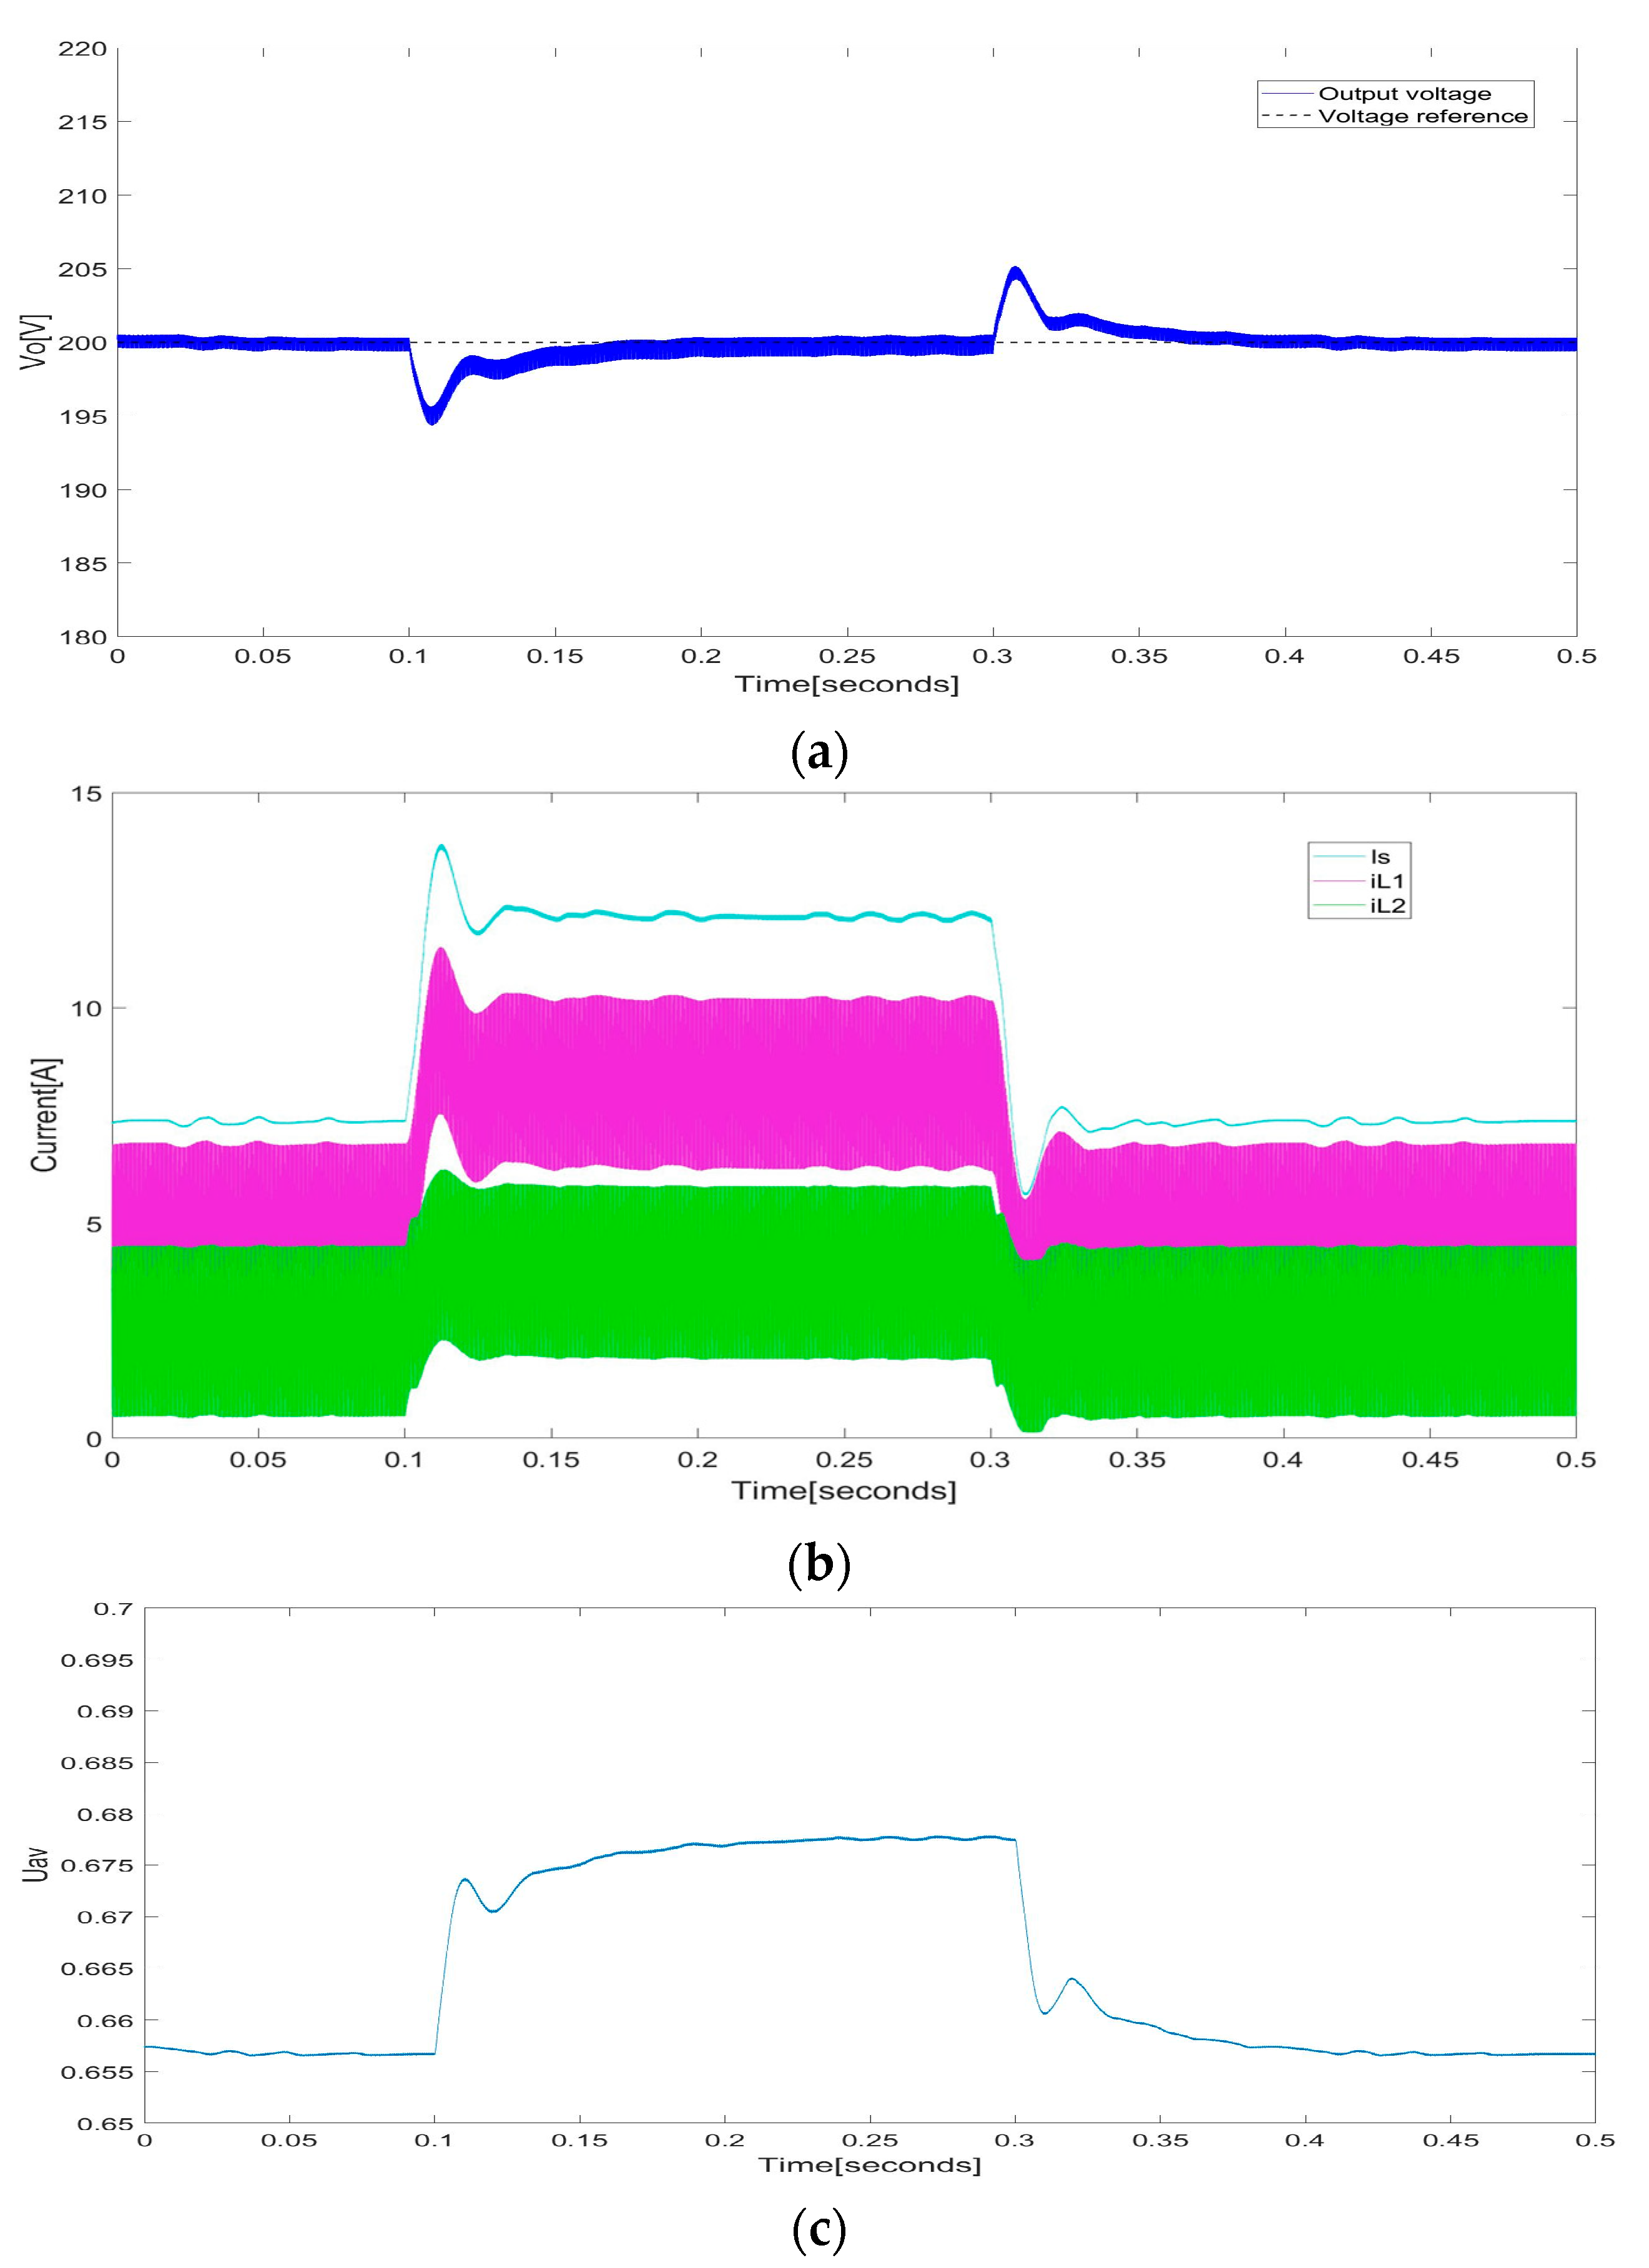
Figure 11 depicts the waveforms of the simulation with a load change. As can be seen, a good dynamic response was obtained. The simulation of load step change was carried out using Simulink/MATLAB. The nominal plant and = 24 V were used to verify the performance of the controller . The simulation configuration parameters were as follows: The fixed-step size was 10 ns, with an ODE 5 (Dormand–Prince) solver, and the sampling time of the voltage controller was 10 us. At time t = 0.1 s, the load changed from 60% to 100%. The load returned to 60% at t = 0.3 s. Overshoot and undershoot were 6 V in both cases, and the settling time was 100 ms in both cases. A limiter can be added to avoid inrush current during startup transient. However, it does not affect the performance of the controller when the system is in the vicinity of the equilibrium point. In the present study, the limiter was included and bounded from 0.05 to 0.75.
Figure 11.
Simulated transient of the proposed DC-DC boost converter under a load step change from 60% to 100% and vice versa: (a) output voltage (blue trace) and reference (dotted line); (b) from top to bottom: input current (cyan trace), inductor current (magenta trace), and inductor current (green trace); (c) control law .
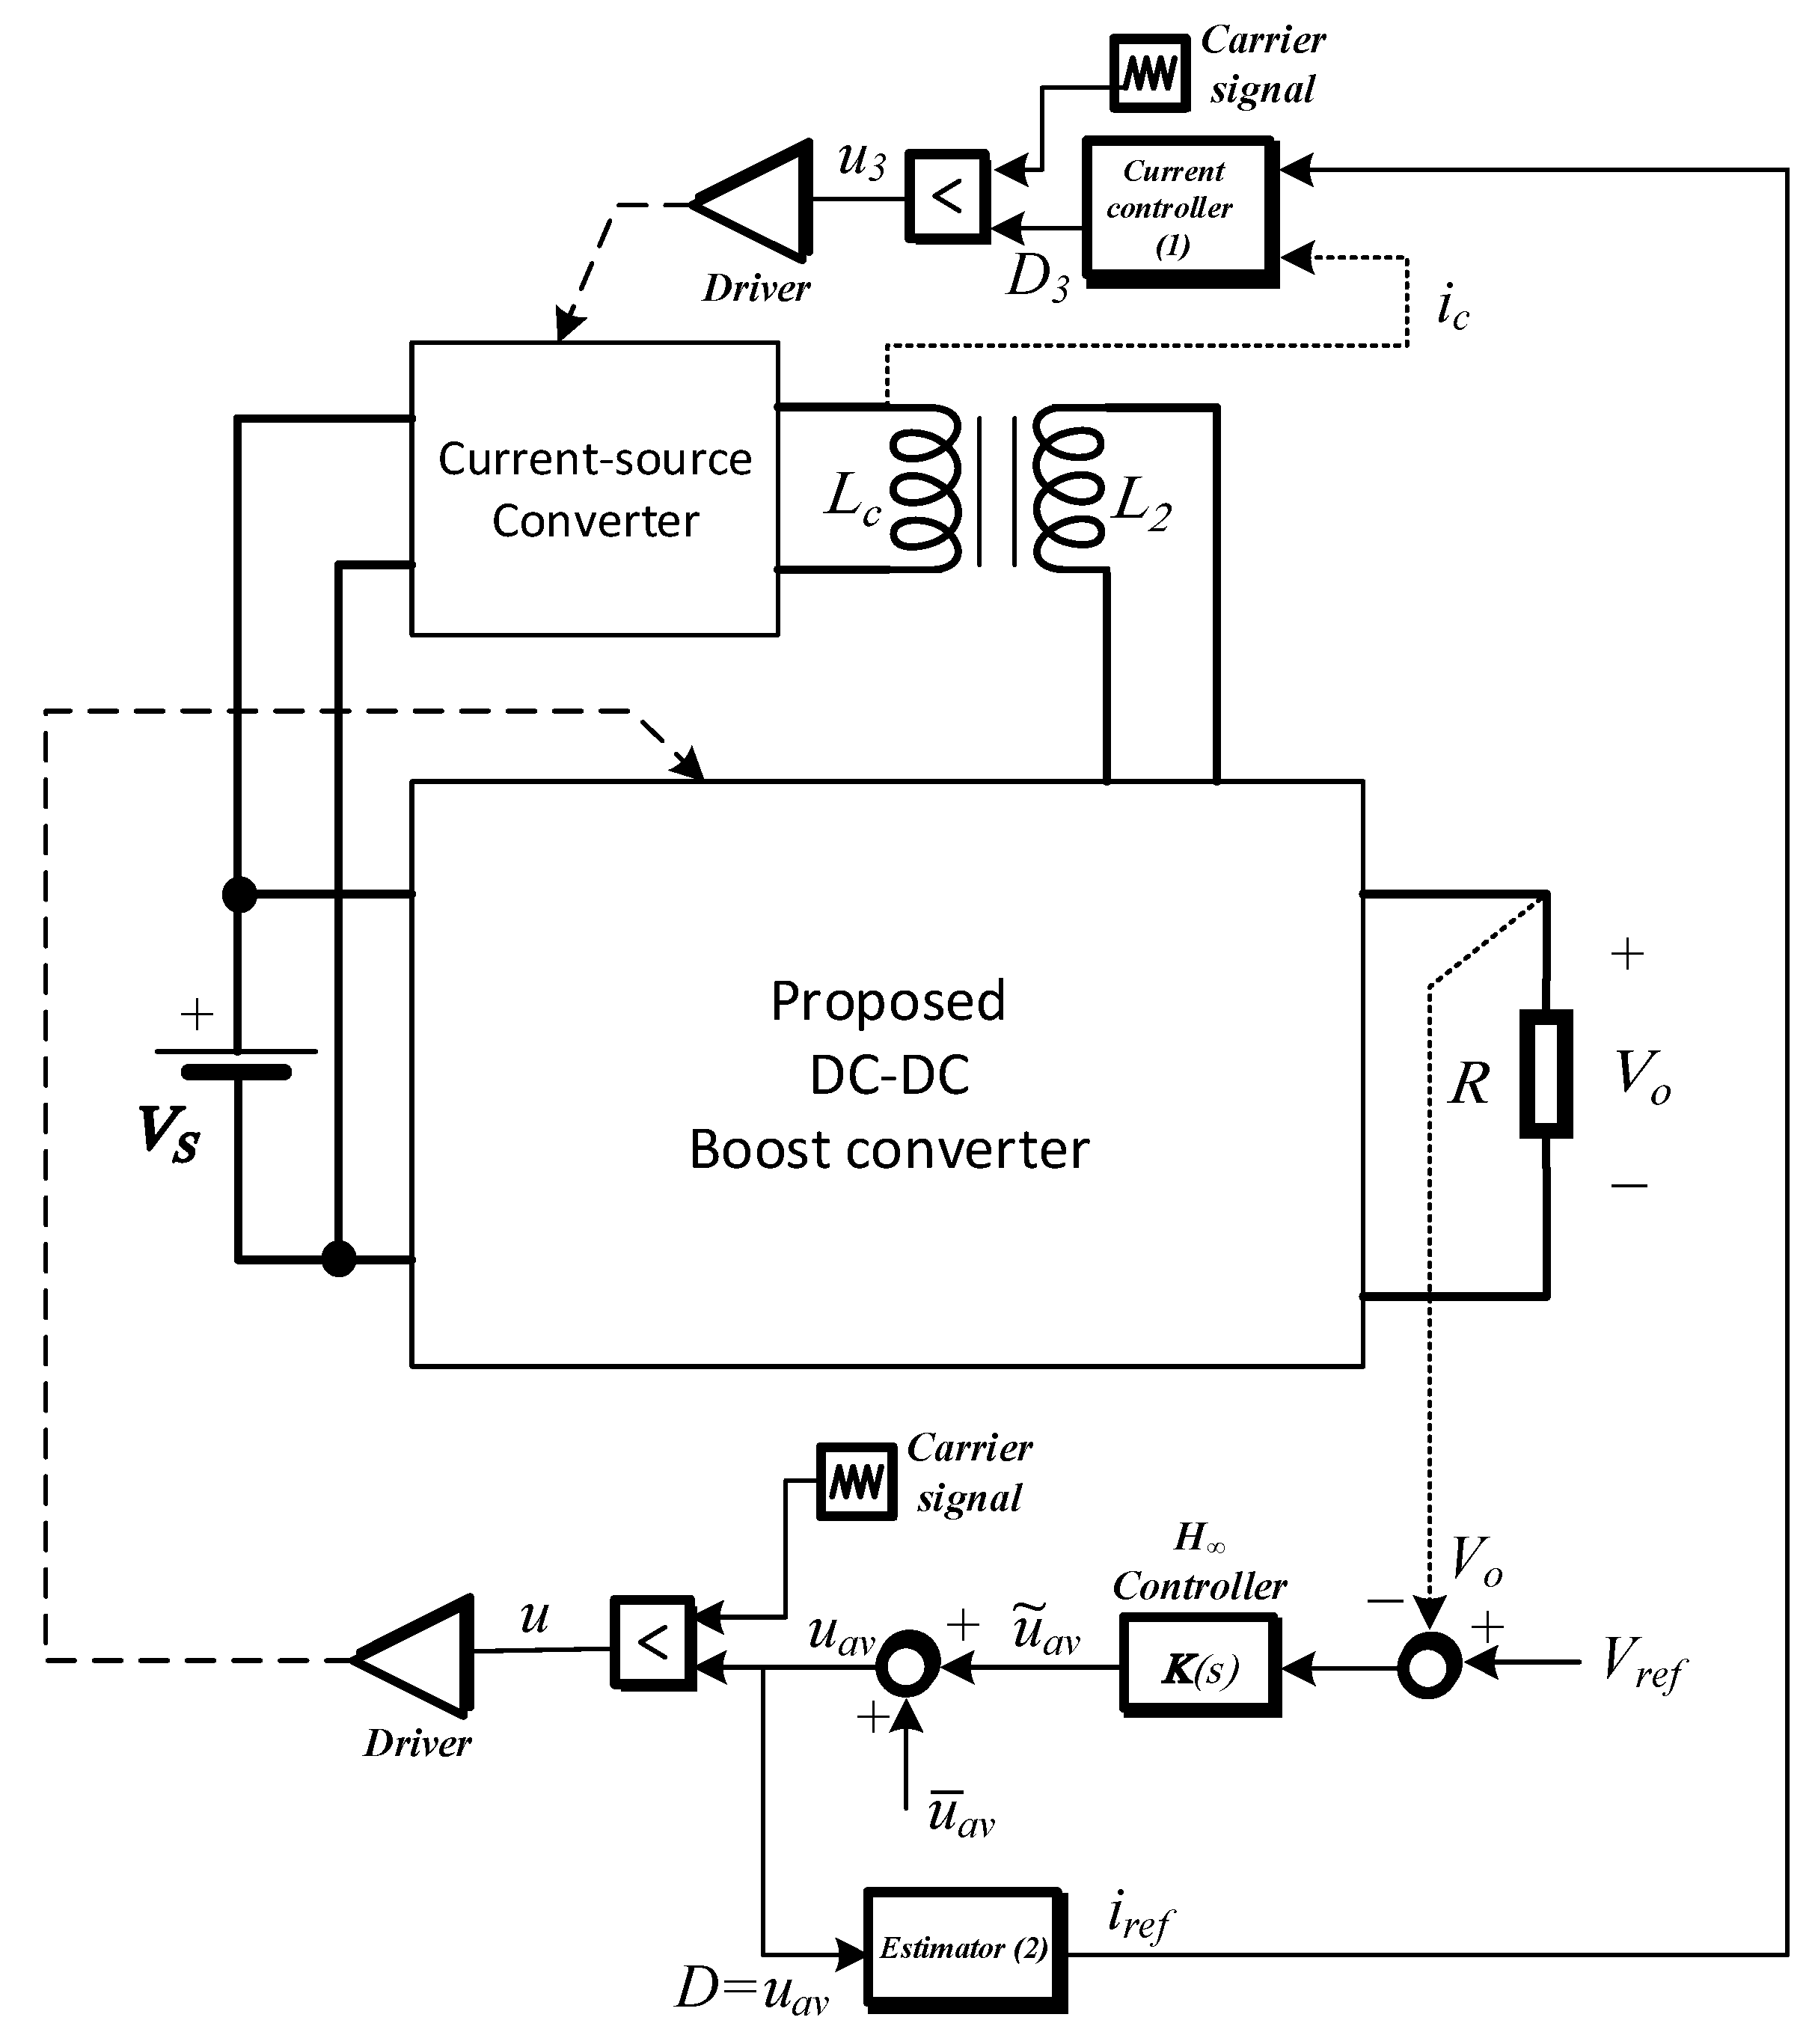
Figure 12 shows the block diagram of the DC–DC converter with the overall control system. The power stage, the VI, and the controller are illustrated, for the main boost converter and the current-source converter.
Figure 12.
Proposed DC–DC converter and its overall control scheme.
5. Experimental Results and Discussion
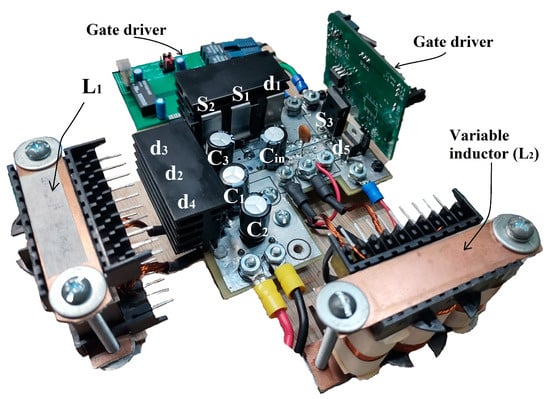
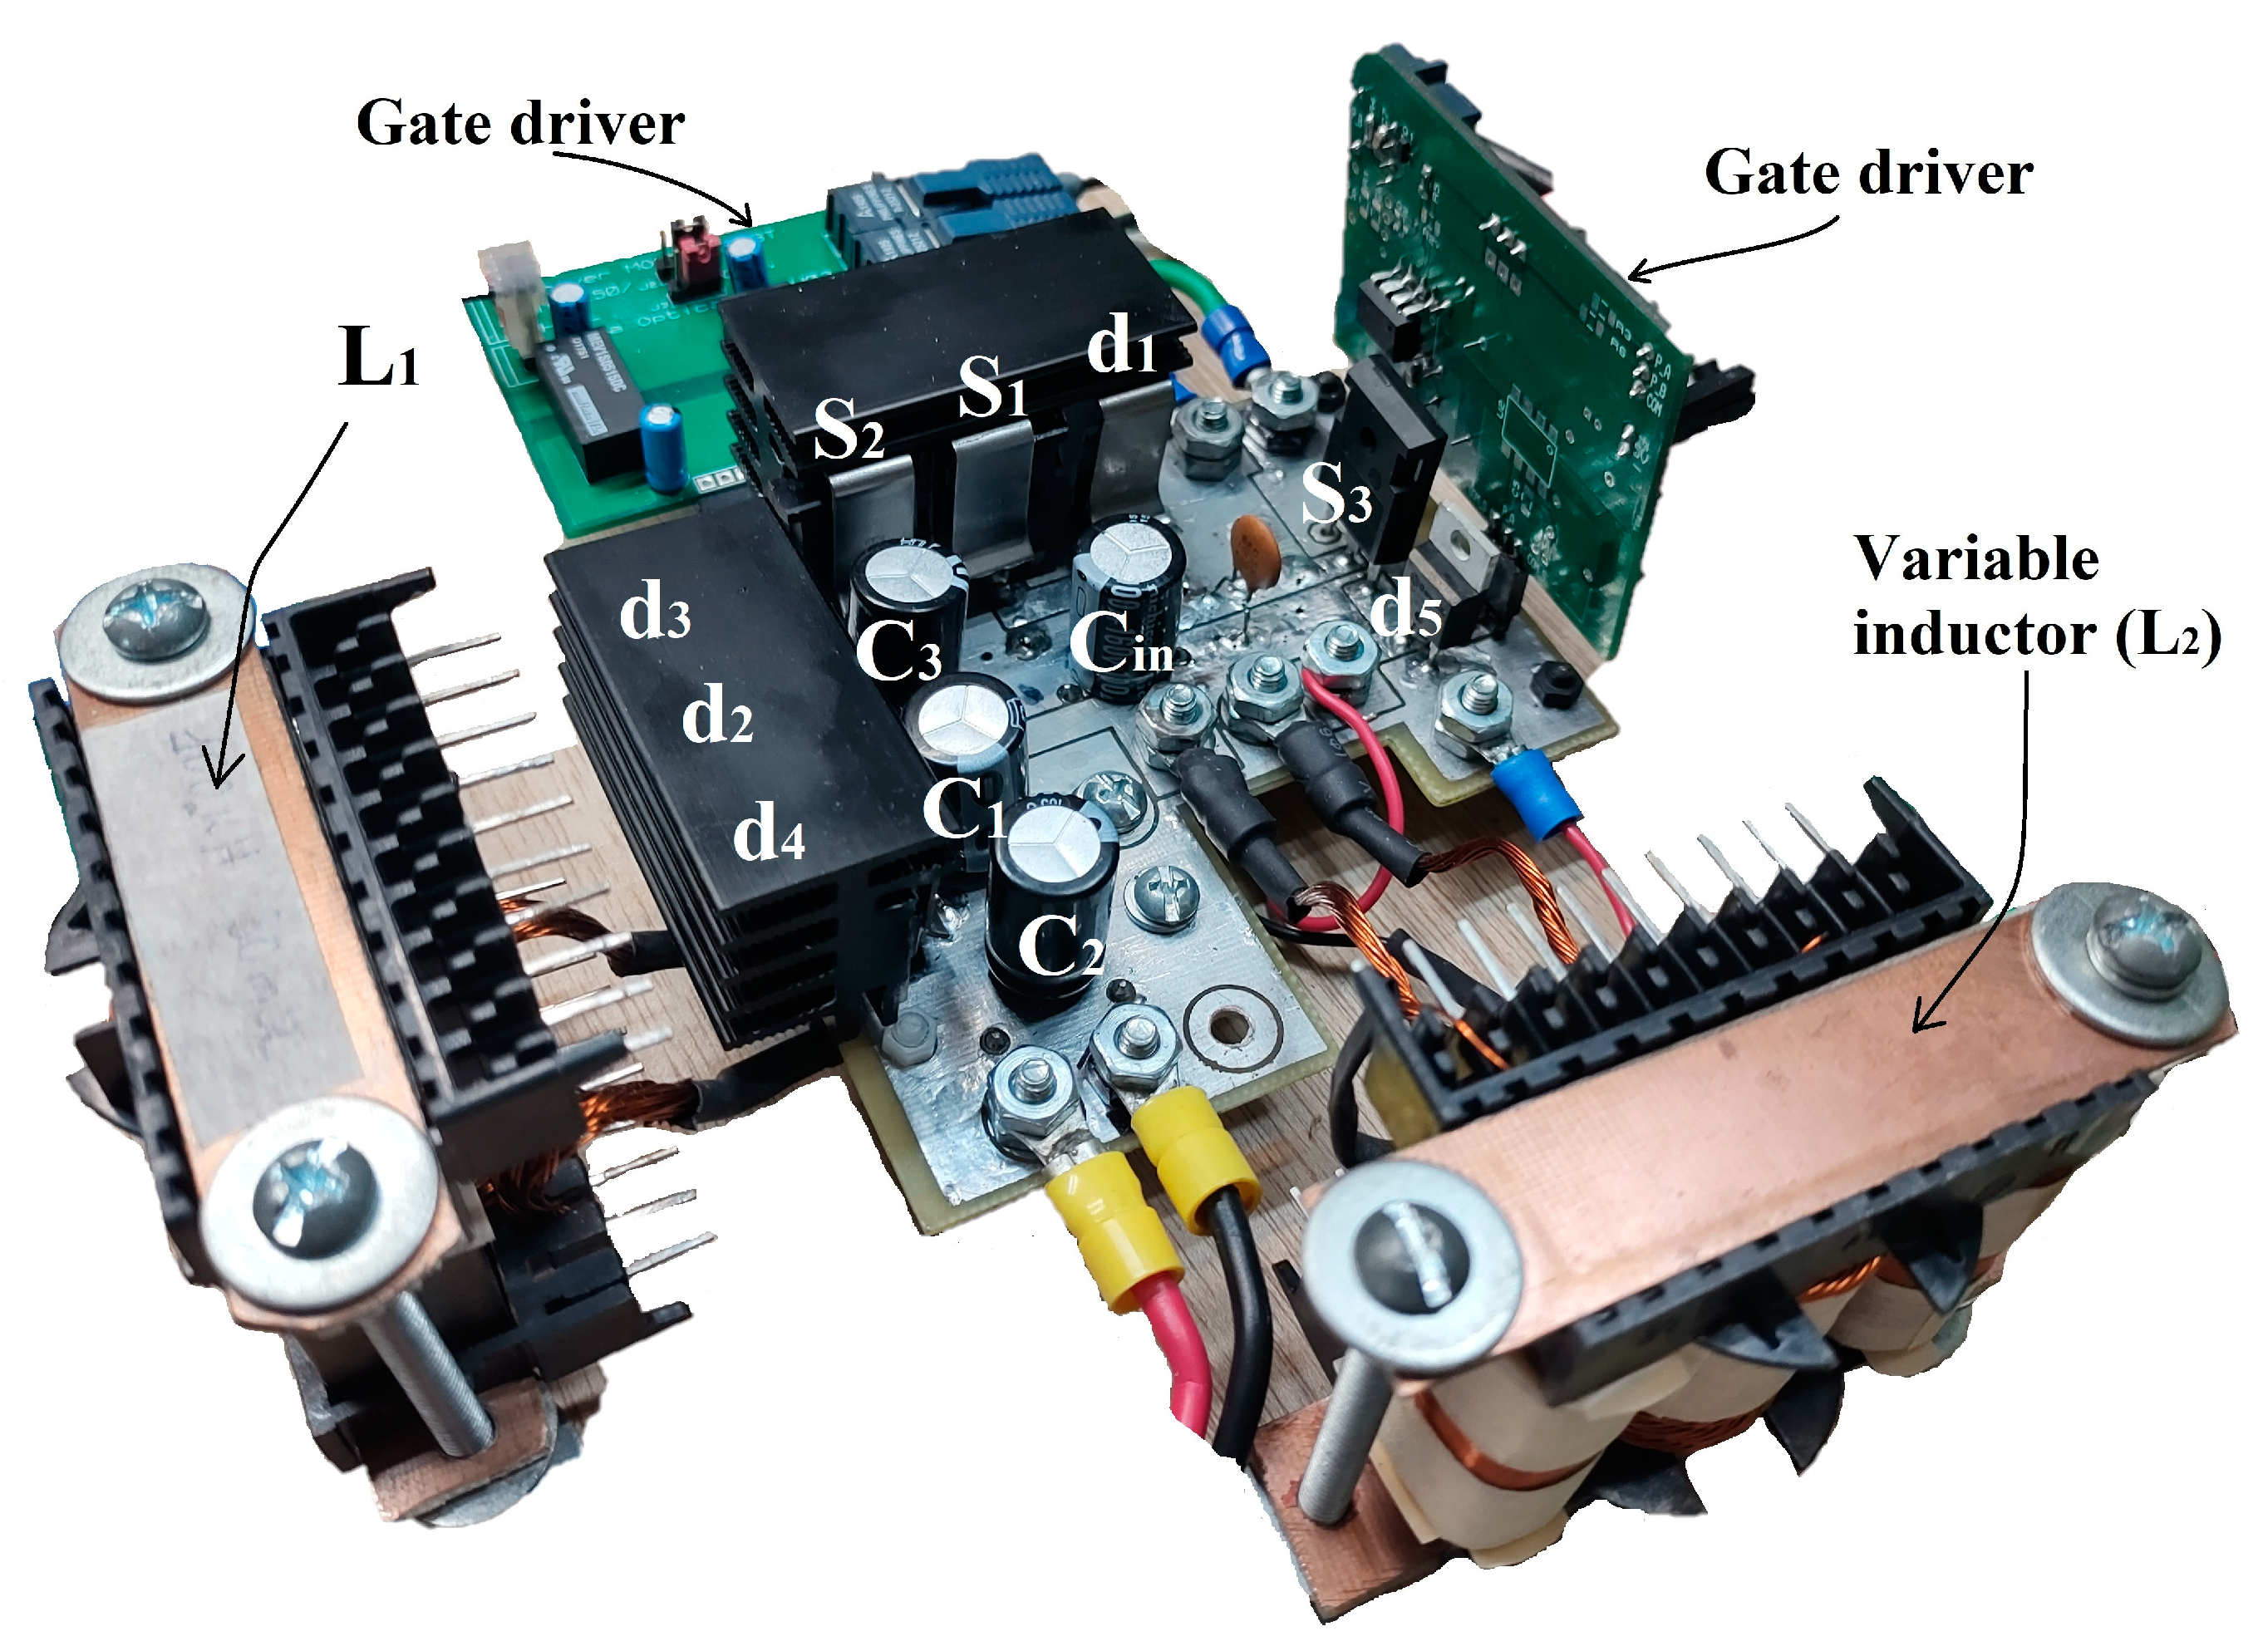
The circuit in Figure 1 was implemented to validate the proposed zero-ripple input current method. Figure 13 and Table 2 show the experimental prototype and specifications, respectively. The controllers were implemented using a CompactRIO embedded system with an NI cRIO-9067 chassis, NI 9223 analog input module, and NI 9401 digital output module.
Figure 13.
Experimental prototype.
Table 2.
Specifications of the prototype.
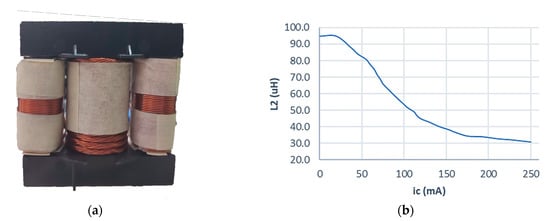
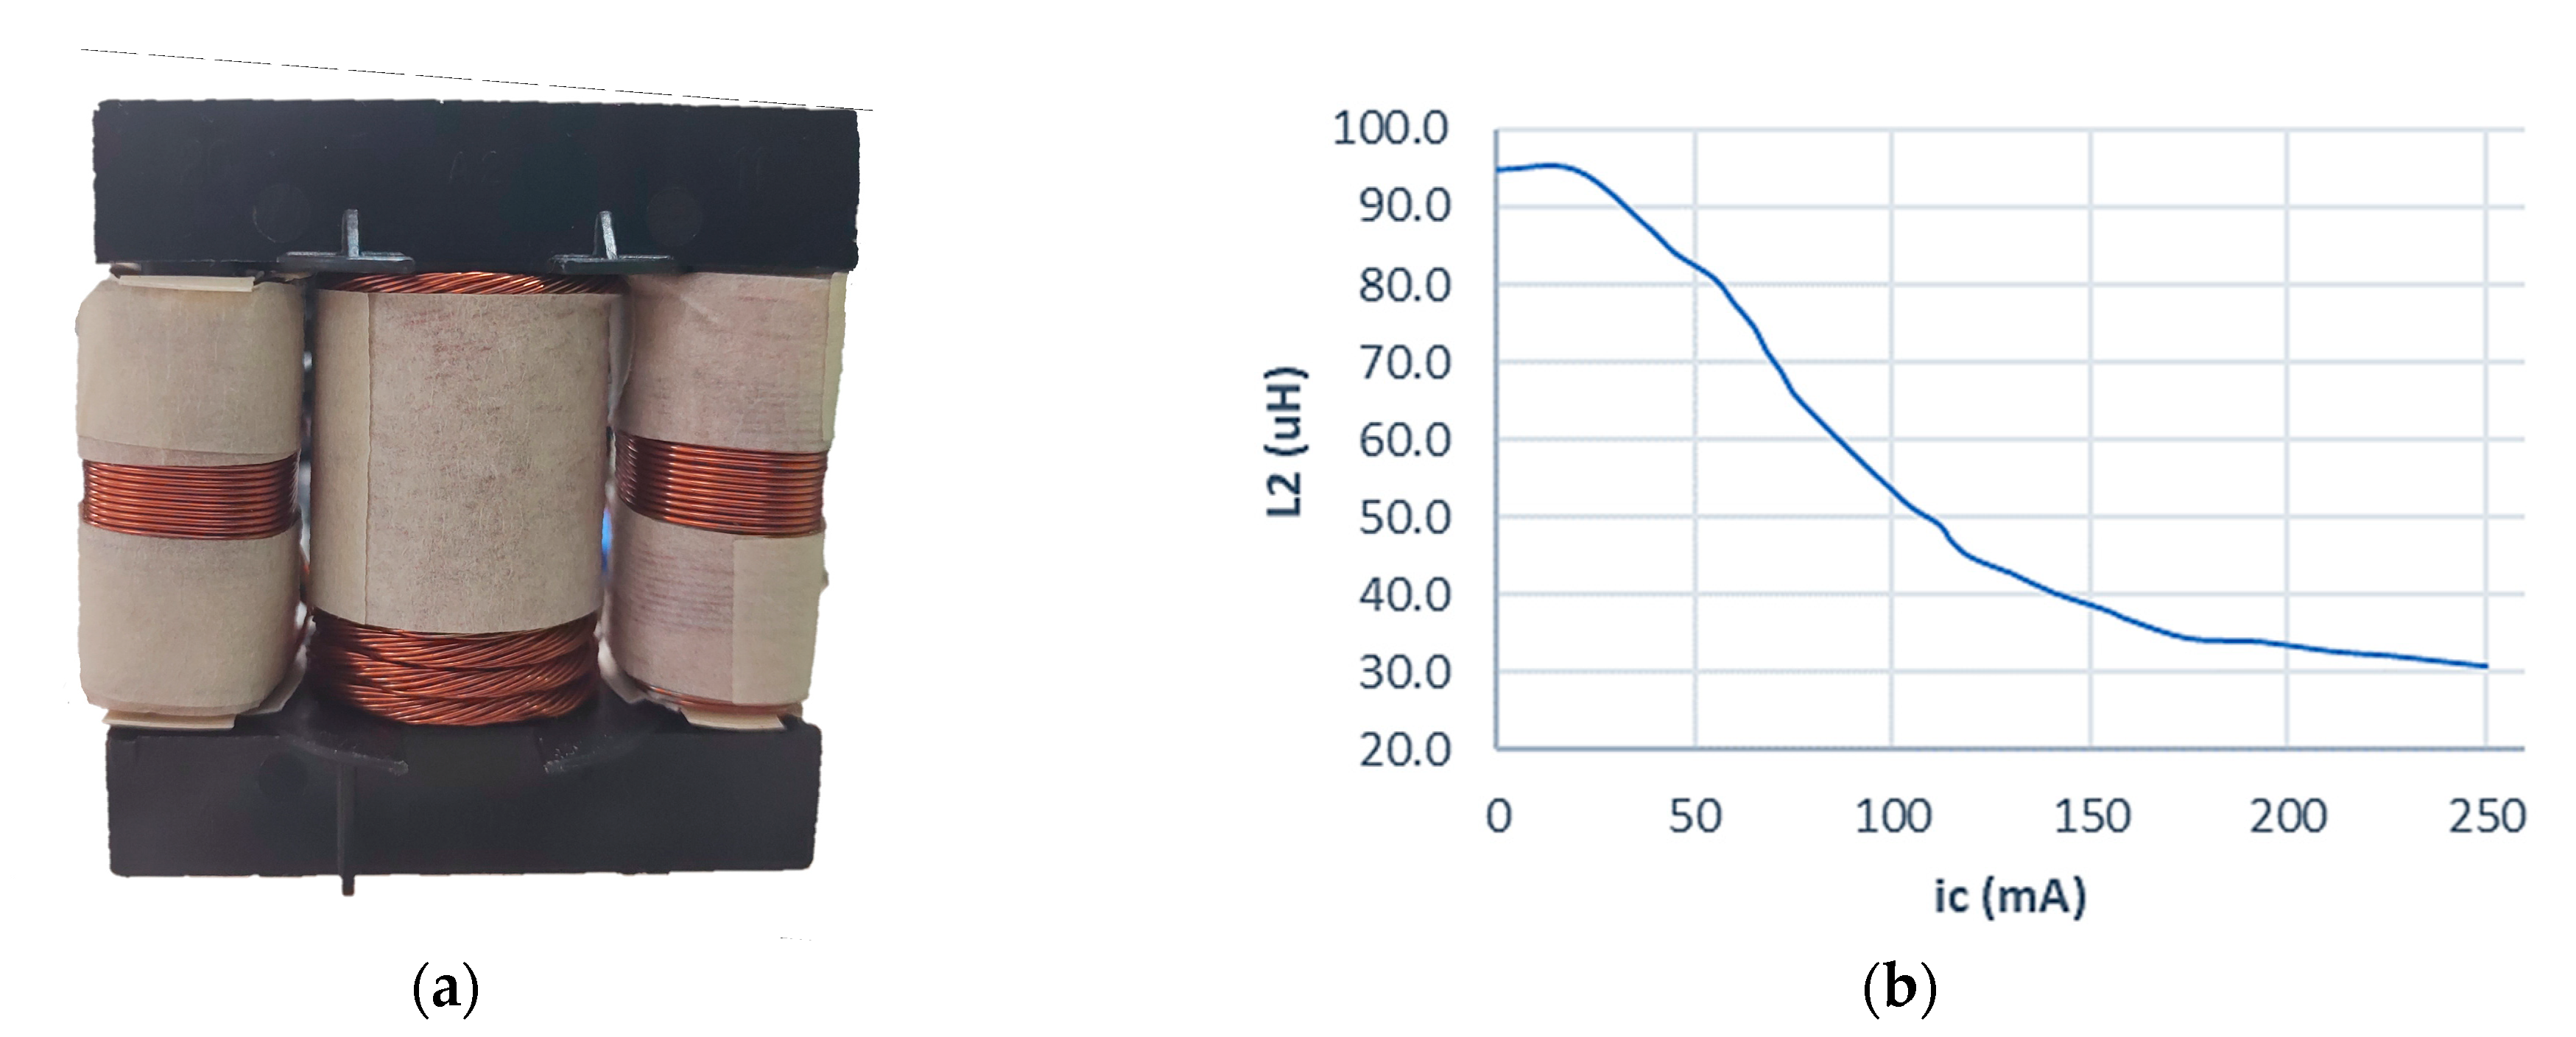
The VI was implemented in an ETD 49/25/16 E-core with 3C90 magnetic material (Figure 14a), = 14, = 153, and the switching frequency for was 20 kHz. The VI controller was set up, incorporating these parameters, with the controller gain = 7. As shown in Figure 14b, the first test for measuring the variable inductance was performed. The input voltage was 24 V, and the proposed converter was loaded with a 220 Ω resistance. The estimator values were obtained from the measurements as follows: = 0.035 A, = 0.130 A, and 65 μH.
Figure 14.
VI graphical representation: (a) prototype; (b) inductance curve.
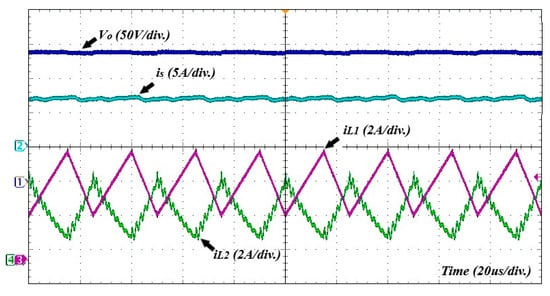
A test with the main converter in an open loop, applying a duty cycle = 0.6, was carried out. Figure 15 shows the waveforms for the proposed converter when loaded with a 220 Ω resistance and an input voltage = 24 V. The average current of both inductors was different; however, the zero-ripple input current was accomplished. As can be observed, the current ripple of the VI is distorted. This is due to many reasons: the core is forced to operate within the limits of the linear and transitional regions, but also with a small unbalanced winding of the arms, which has an impact on the magnetic reluctance and the parasitic capacitance of the windings in high frequency [29].
Figure 15.
Open-loop waveforms. From top to bottom: output voltage (blue trace), input current (cyan trace), inductor current (magenta trace), and inductor current (green trace); test at = 0.6.
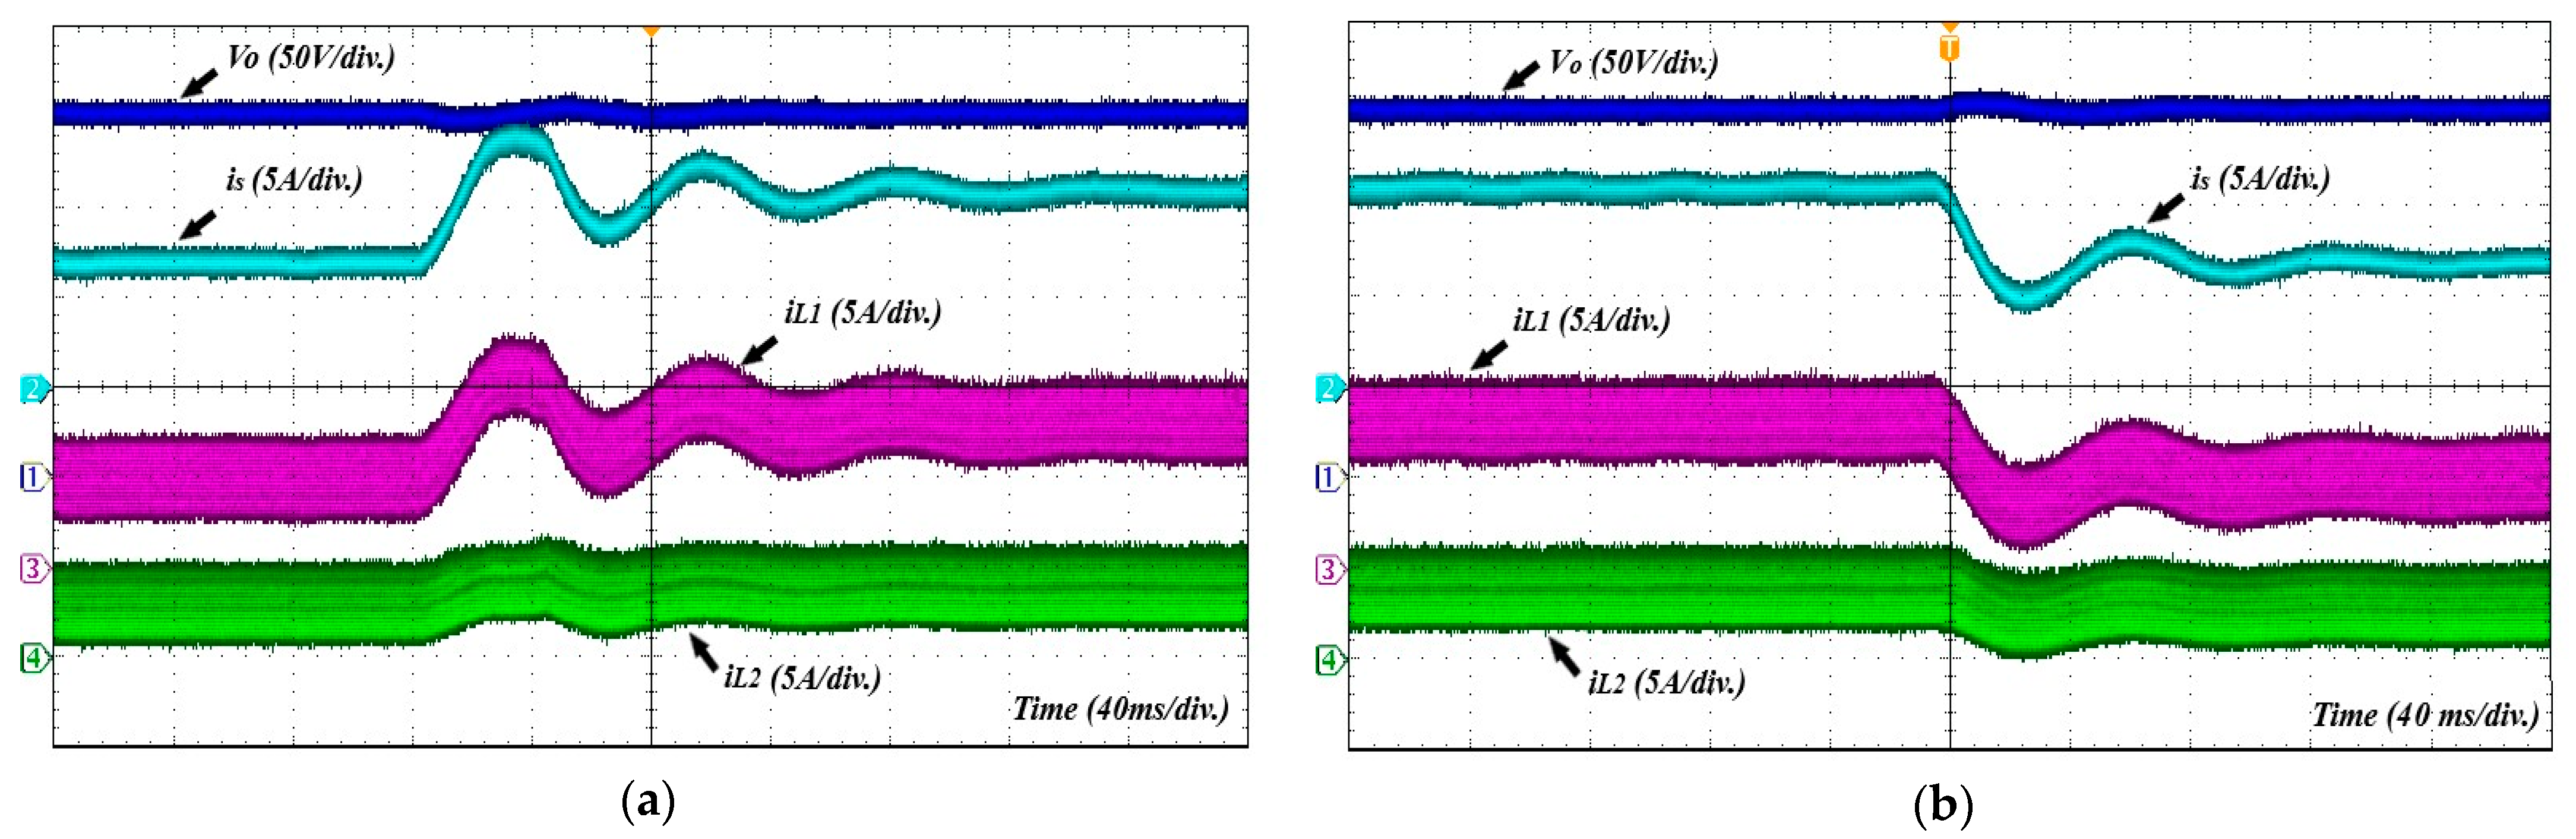
Figure 16 shows the dynamic response of the proposed converter under the action of the robust PI controller. The output load changed from 60% to 100% and vice versa, while the reference voltage was 200 V. In this test, the inductance varied in the function of the duty cycle to guarantee the ICR elimination. As can be observed, variation in the inductance parameter value did not cause a significant change in performance or stability. The voltage overshoot and undershoot was about 8 V. The settling time was about 120 ms, which is a good response for boost converters with high gain, but it should also be noted that the overvoltage or undervoltage was small.
Figure 16.
Transient response under load variation. From top to bottom: output voltage (blue trace), input current (cyan trace), inductor current (magenta trace), and inductor current (green trace): (a) from 60% to 100%; (b) from 100% to 60%.
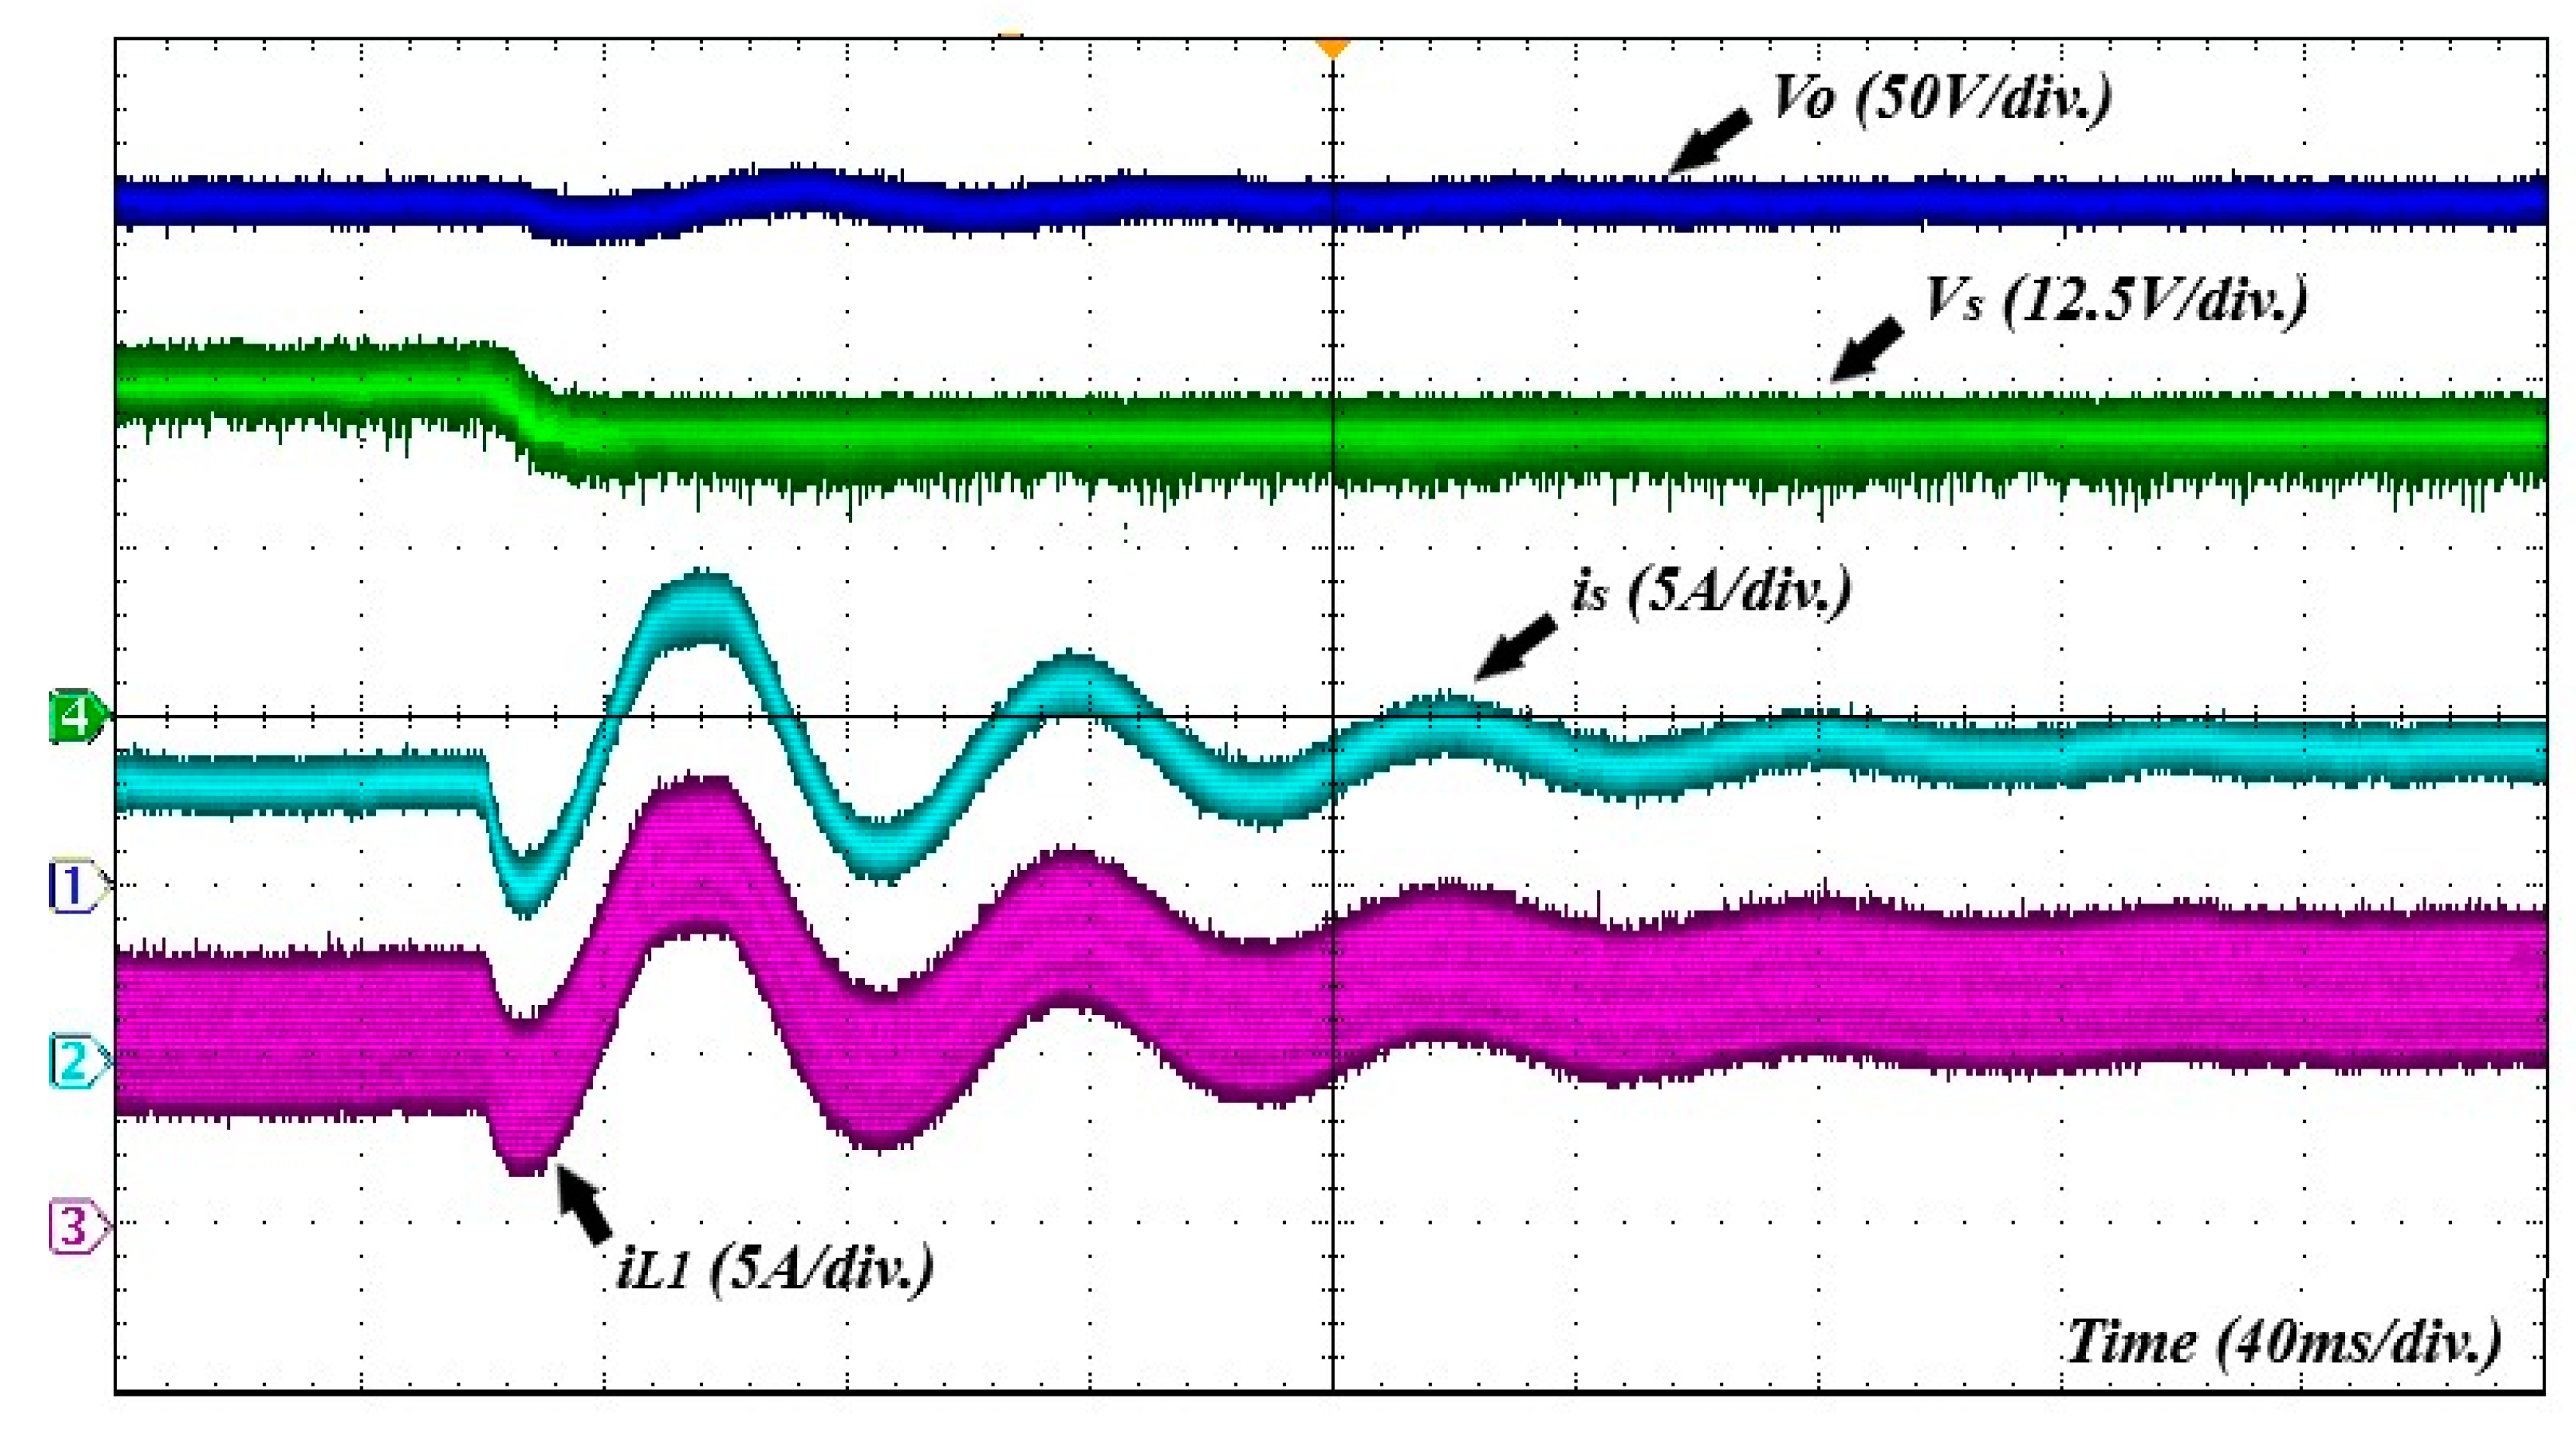
Figure 17 shows the voltage regulation under the robust PI controller. This figure demonstrates the output voltage response when the input voltage changed from 24 V to 21 V. According to the voltage variation test, it can be concluded that the zero-ripple input current during the transient response was maintained.
Figure 17.
Transient response under input voltage change. From top to bottom: output voltage (blue trace), input voltage (green trace), input current (cyan trace), and inductor current (magenta trace).
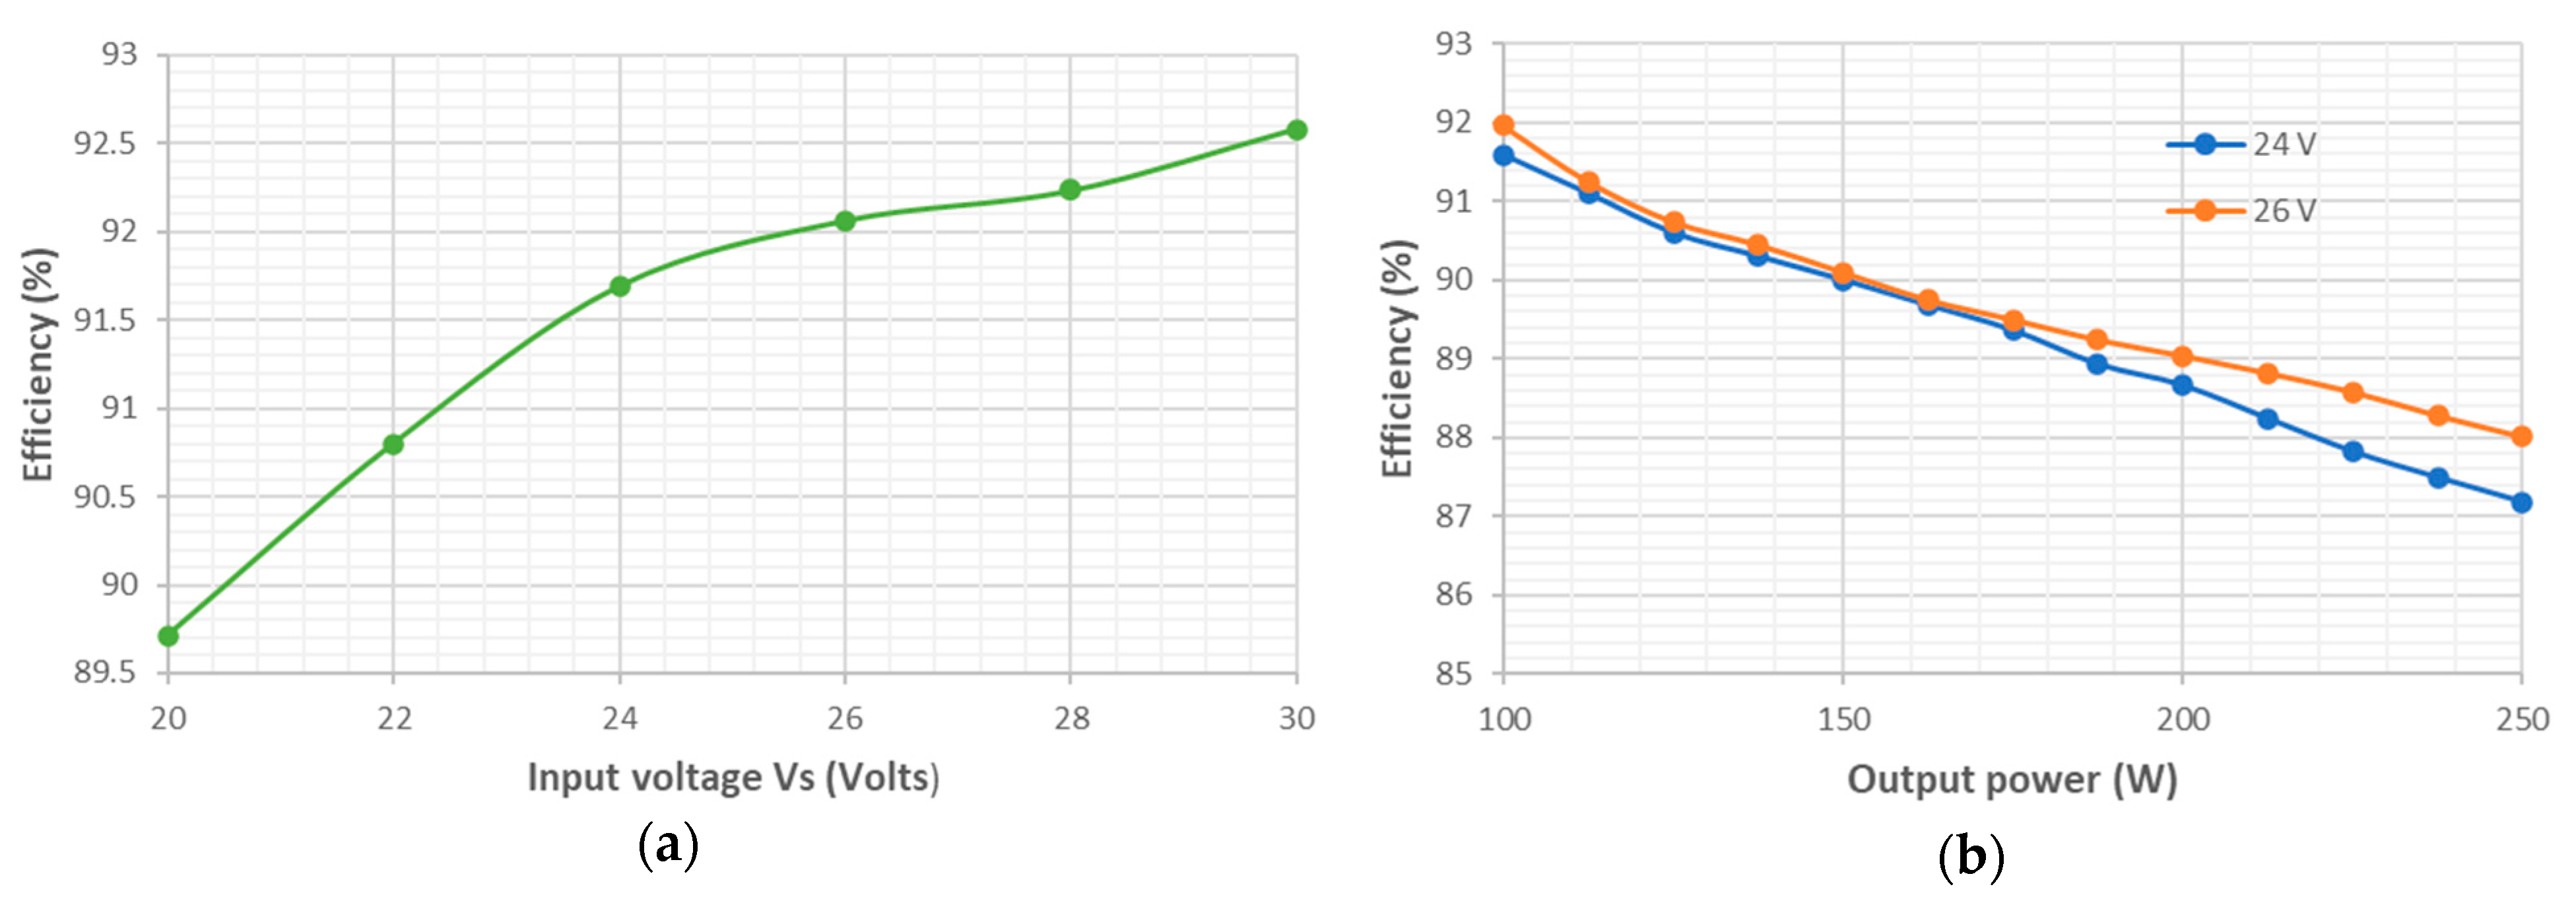
Figure 18 shows the efficiency test of the proposed boost converter. In Figure 18a, with a constant load of 100 W, the efficiency was tested at different input voltages, which indicates that the higher the input voltage was, the higher the efficiency would be. In this test, the voltage gain was maintained at a constant value of 8. Additionally, a comparison of the measured efficiency with different output powers is depicted in Figure 18b. For this test, two input voltages and a 200 V nominal output voltage were applied. The efficiency values presented were all measured using the Chroma 62204 power meter.
Figure 18.
Efficiency test of the converter: (a) efficiency test for different input voltages; (b) efficiency test for different output loads.
Table 3 compares the proposed DC–DC boost converter with state-of-the-art topologies in terms of gain, the number of power components, ICR elimination, frequency, and efficiency. Considering that the current-source converter power consumption is low, the number of active devices of the proposed converter is similar to other converters. In addition, the proposed topology presents the least number of passive components.
Table 3.
Comparison of different types of high voltage gain converters.
In [21], a similar converter had a worse performance when the PI controller was tuned using another approach. The proposed PI, which is based on , exhibited a settling time of 120 ms, whereas the adaptive PI controller in [22] had a settling time of 160 ms.
With this proposal, the input current ripple can be eliminated in a wide operating region in transitory and steady states. Voltage regulation can be attained with a simple control loop. However, a low efficiency at low voltage was obtained due to and . The inductance, which could be varied, had a superimposed high-frequency ripple. This ripple was noticeable when the control current was zero, and the switching frequency increased.
6. Conclusions and Future Works
In this paper, a zero-ripple input current boost converter using a VI was introduced. The converter presents a high voltage gain and wide operating region with zero-ripple condition. The sizing of the components was introduced to minimize the impact of the volume of the circuit. Moreover, a dynamical model including the effect of switched capacitors in the multiplier cell was presented. All dynamical models were validated via simulation. To address the parameter variation and external perturbations, a robust PI controller was designed based on the theory.
Experimental results revealed that a simple control loop should be employed to regulate the output voltage. The current ripple reduction capability occurs not only under the operating point for traditional two-phase interleaved converters but also in a duty cycle greater than 50%. The main feature of the proposed converter is that it has great potential to be used in renewable sources, where high voltage gain and lower current ripple are required.
In future research, it might be possible to study alternative methods to eliminate the high-frequency ripple superimposed in the VI. Additionally, a soft switching method can be included to increase global efficiency. Another type of VI or nonlinear inductor can also be explored as a case study. Additionally, the implementation of another control approach with the advantage of directly using the nonlinear model of the DC–DC converter should be explored.
Author Contributions
Conceptualization, H.H. (Hector Hidalgo) and N.V.; investigation, H.H. (Hector Hidalgo); methodology, N.V. and H.H. (Hector Hidalgo); supervision, N.V., R.O., H.H. (Héctor Huerta) and S.P.; writing—original draft preparation, H.H. (Hector Hidalgo); writing—review and editing, N.V., S.P. and C.H.; sponsorship, N.V. and C.H. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by TecNM (grant number 16984.23-P) and Idea Guanajuato (grant number pending).
Data Availability Statement
Data are contained in the paper.
Conflicts of Interest
The authors declare no conflict of interest.
Nomenclature
| Allowable steady-state error | |
| System matrix | |
| Input matrix for voltage gain transfer function | |
| Input matrix for audio susceptibility transfer function | |
| Output matrix | |
| The capacitance of each capacitor in the voltage multiplier | |
| Duty cycle | |
| Unstructured uncertainty | |
| Voltage ripple of | |
| ESR | Equivalent series resistance |
| Current controller gain | |
| Lower linear fractional transformation | |
| Uncertain plant | |
| Voltage gain transfer function | |
| Audio susceptibility transfer function | |
| Output function | |
| Control current | |
| ICR | Input current ripple |
| Voltage controller | |
| LFT | Linear fractional transformation |
| Ideal gain | |
| Practical gain | |
| Generalized plant | |
| PI | Proportional–integral controller |
| Switching function | |
| Average control input | |
| Linearized average control input | |
| Equilibrium average control input | |
| VI | Variable inductor |
| Exogenous input | |
| State vector | |
| Linearized state vector | |
| Equilibrium point vector | |
| System output | |
| Linearized output | |
| Error signal vector |
References
- Rajesh, R.; Prabaharan, N. Design of New Nonisolated High Gain Converter for Higher Power Density. Int. Trans. Electr. Energy Syst. 2023, 2023, 2011926. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.-E.; Tai, C.-H. Novel Bidirectional Isolated DC/DC Converter with High Gain Ratio and Wide Input Voltage for Electric Vehicle Storage Systems. Batteries 2022, 8, 240. [Google Scholar] [CrossRef] [Scilit]
- Khan, R.A.; Liu, H.-D.; Lin, C.-H.; Lu, S.-D.; Yang, S.-J.; Sarwar, A. A Novel High-Voltage Gain Step-Up DC–DC Converter with Maximum Power Point Tracker for Solar Photovoltaic Systems. Processes 2023, 11, 1087. [Google Scholar] [CrossRef] [Scilit]
- Mumtaz, F.; Yahaya, N.Z.; Meraj, S.T.; Singh, N.S.S.; Rahman, S.; Hossain, L. A High Voltage Gain Interleaved DC-DC Converter Integrated Fuel Cell for Power Quality Enhancement of Microgrid. Sustainability 2023, 15, 7157. [Google Scholar] [CrossRef] [Scilit]
- Lotfi Nejad, M.; Poorali, B.; Adib, E.; Motie Birjandi, A.A. New Cascade Boost Converter with Reduced Losses. IET Power Electron. 2016, 9, 1213–1219. [Google Scholar] [CrossRef] [Scilit]
- Divya Navamani, J.; Lavanya, A.; Almakhles, D.; Jagabar Sathik, M. A Review on Segregation of Various High Gain Converter Configurations for Distributed Energy Sources. Alex. Eng. J. 2022, 61, 675–700. [Google Scholar] [CrossRef] [Scilit]
- Leyva-Ramos, J.; Mota-Varona, R.; Ortiz-Lopez, M.G.; Diaz-Saldierna, L.H.; Langarica-Cordoba, D. Control Strategy of a Quadratic Boost Converter with Voltage Multiplier Cell for High-Voltage Gain. IEEE J. Emerg. Sel. Top Power Electron. 2017, 5, 1761–1770. [Google Scholar] [CrossRef] [Scilit]
- Meraj, M.; Bhaskar, M.S.; Iqbal, A.; Al-Emadi, N.; Rahman, S. Interleaved Multilevel Boost Converter with Minimal Voltage Multiplier Components for High-Voltage Step-Up Applications. IEEE Trans. Power Electron. 2020, 35, 12816–12833. [Google Scholar] [CrossRef] [Scilit]
- Forouzesh, M.; Siwakoti, Y.P.; Gorji, S.A.; Blaabjerg, F.; Lehman, B. A Survey on Voltage Boosting Techniques for Step-up DC-DC Converters. In Proceedings of the 2016 IEEE Energy Conversion Congress and Exposition (ECCE), Milwaukee, WI, USA, 18–22 September 2016; pp. 1–8. [Google Scholar]
- de Carvalho, M.R.S.; Neto, R.C.; Barbosa, E.J.; Limongi, L.R.; Bradaschia, F.; Cavalcanti, M.C. An Overview of Voltage Boosting Techniques and Step-Up DC-DC Converters Topologies for PV Applications. Energies 2021, 14, 8230. [Google Scholar] [CrossRef] [Scilit]
- Akhormeh, A.R.N.; Abbaszadeh, K.; Moradzadeh, M.; Shahirinia, A. High-Gain Bidirectional Quadratic DC–DC Converter Based on Coupled Inductor with Current Ripple Reduction Capability. IEEE Trans. Ind. Electron. 2021, 68, 7826–7837. [Google Scholar] [CrossRef] [Scilit]
- Wong, Y.-S.; Chen, J.-F.; Liu, K.-B.; Hsieh, Y.-P. A Novel High Step-Up DC-DC Converter with Coupled Inductor and Switched Clamp Capacitor Techniques for Photovoltaic Systems. Energies 2017, 10, 378. [Google Scholar] [CrossRef] [Scilit]
- Yan, F.; Li, J.; Du, C.; Zhao, C.; Zhang, W.; Zhang, Y. A Coupled-Inductor DC-DC Converter with Input Current Ripple Minimization for Fuel Cell Vehicles. Energies 2019, 12, 1689. [Google Scholar] [CrossRef] [Scilit]
- Villarreal-Hernandez, C.A.; Loranca-Coutiño, J.; Mayo-Maldonado, J.C.; Valdez-Resendiz, J.E.; García-Vite, P.M.; Valderrabano-Gonzalez, A.; Rosas-Caro, J.C. A Double Dual Boost Converter with Switching Ripple Cancellation for PEMFC Systems. Electronics 2020, 9, 1592. [Google Scholar] [CrossRef] [Scilit]
- Li, Q.; Huangfu, Y.; Xu, L.; Wei, J.; Ma, R.; Zhao, D.; Gao, F. An Improved Floating Interleaved Boost Converter with the Zero-Ripple Input Current for Fuel Cell Applications. IEEE Trans. Energy Convers. 2019, 34, 2168–2179. [Google Scholar] [CrossRef] [Scilit]
- Ahmed, N.A.; Alajmi, B.N.; Abdelsalam, I.; Marei, M.I. Soft Switching Multiphase Interleaved Boost Converter with High Voltage Gain for EV Applications. IEEE Access 2022, 10, 27698–27716. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.; Qu, L.; Tong, Q.; Jia, G. Novel Filter Approach for Ripple-Free Input Current Boost Converters Based on Variable Inductors. J. Power Electron. 2023, 1–13. [Google Scholar] [CrossRef] [Scilit]
- Hidalgo, H.; Vázquez, N.; Orosco, R.; Huerta-Ávila, H.; Pinto, S.; Estrada, L. Floating Interleaved Boost Converter with Zero-Ripple Input Current Using Variable Inductor. Technologies 2023, 11, 21. [Google Scholar] [CrossRef] [Scilit]
- Beraki, M.W.; Trovão, J.P.F.; Perdigão, M.S. Performance Enhancement of Powertrain DC–DC Converter Using Variable Inductor. IET Electr. Syst. Transp. 2021, 11, 161–170. [Google Scholar] [CrossRef] [Scilit]
- Martins, S.; Seidel, Á.R.; Perdigão, M.S.; Roggia, L. Core Volume Reduction Based on Non-Linear Inductors for a PV DC–DC Converter. Electr. Power Syst. Res. 2022, 213, 108716. [Google Scholar] [CrossRef] [Scilit]
- Sureshkumar, A.; Gunabalan, R. Design of Robust Guaranteed Margin Stability Region PI Controller for Automotive LED Lighting with Parameter Uncertainty. IEEE Access 2022, 10, 15657–15670. [Google Scholar] [CrossRef] [Scilit]
- Yanarates, C.; Zhou, Z. Design and Cascade PI Controller-Based Robust Model Reference Adaptive Control of DC-DC Boost Converter. IEEE Access 2022, 10, 44909–44922. [Google Scholar] [CrossRef] [Scilit]
- Khayat, Y.; Naderi, M.; Shafiee, Q.; Batmani, Y.; Fathi, M.; Bevrani, H. Robust Control of a DC-DC Boost Converter: H2 and H Techniques. In Proceedings of the 2017 8th Power Electronics, Drive Systems & Technologies Conference (PEDSTC), Mashhad, Iran, 14–16 February 2017; pp. 407–412. [Google Scholar]
- Shaw, P.; Veerachary, M. Mixed-Sensitivity Based Robust H∞ Controller Design for High-Gain Boost Converter. In Proceedings of the 2017 International Conference on Computer, Communications and Electronics (Comptelix), Jaipur, India, 1–2 July 2017; pp. 612–617. [Google Scholar]
- Villarreal-Hernandez, C.A.; Ruiz-Martinez, O.F.; Mayo-Maldonado, J.C.; Escobar, G.; Valdez-Resendiz, J.E.; Rosas-Caro, J.C. Minimum Current Ripple Point Tracking Control for Interleaved Dual Switched-Inductor DC–DC Converters. IEEE Trans. Ind. Electron. 2021, 68, 175–185. [Google Scholar] [CrossRef] [Scilit]
- Skogestad, S.; Postlethwaite, I. Multivariable Feedback Control: Analysis and Design, 2nd ed.; Wiley: Chichester, West Sussex, England, 2005. [Google Scholar]
- Gahinet, P.; Apkarian, P. Structured H∞ Synthesis in MATLAB. IFAC Proc. Vol. 2011, 44, 1435–1440. [Google Scholar] [CrossRef] [Scilit]
- Dulau, M.; Oltean, S.-E. The Effects of Weighting Functions on the Performances of Robust Control Systems. In Proceedings of the 14th International Conference on Interdisciplinarity in Engineering—INTER-ENG 2020, Târgu Mureș, Romania, 25 December 2020; MDPI: Basel, Switzerland, 2020; p. 46. [Google Scholar]
- Saeed, S.; Georgious, R.; Garcia, J. Modeling of Magnetic Elements Including Losses—Application to Variable Inductor. Energies 2020, 13, 1865. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2023 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).