


Abstract
The high penetration of wind power decreases the system inertia and primary frequency reserve while replacing the conventional synchronous generators (SGs). Therefore, if the system operator does not take appropriate action on the remaining generation units (GUs) operation, high penetration of wind power will aggravate the frequency stability. To solve this problem, wind power plants (WPPs) may provide the inertial response and primary frequency response (PFR) to support the frequency stability. However, due to the variability of renewable energy, WPPs may not provide adequate frequency response whenever it is required. This paper proposes an algorithm to determine the operation of GUs to provide appropriate PFR for a power system with high penetration of wind power. Through the proposed algorithm, it calculates the required PFR to restore the decreased frequency stability caused by the high penetration of wind power. Then, while considering the available PFR from WPPs, it redetermines the droop coefficient of SGs governor to provide the sufficient PFR to recover the frequency stability. Finally, the effectiveness of the proposed algorithm is verified on the practical Korean electric power system.
1. Introduction
Following the global trend of increasing the hosting capacity of the wind power plants (WPPs) to solve environmental and economic issues, the government of Korea is planning to increase the capacity of WPPs to 17.7 GW by 2030 [1,2]. However, various stability problems are being reported due to the uncertainty and variability of renewable energy generation [3]. In particular, the high penetration of wind power decreases the system inertia and the amount of primary frequency reserve, adversely impacting frequency stability. Moreover, when analyzing the frequency stability, frequency nadir (fnadir) and settling frequency (fset) are considered for the dynamic and steady state, respectively [4,5,6]. In order to maintain the frequency stability in the Korean electric power system, these two indices need to be above 59 Hz and 59.8 Hz to prevent under-frequency load shedding relay and activate automatic generation control (AGC), respectively. Therefore, the operation of generation units (Gus), including both conventional synchronous generators (SGs) and newly installed distributed generators (DGs), must be appropriately determined to maintain frequency stability [7].
In a steady-state condition, WPPs are normally operated by the maximum power point tracking (MPPT) control method [8]. However, WPPs operating in this method do not provide any frequency responses when a large disturbance such as a generation trip occurs. Therefore, as WPPs replace conventional SGs, which provide an inertial response (IR) and primary frequency response (PFR), frequency stability is severely impacted [9,10]. To solve this problem, many studies have developed effective control methods to provide ancillary services and support power system stability [11,12,13,14]. In particular, inertial control methods are developed for WPPs to provide IR by the stored kinetic energy in the rotating masses supporting the dynamic frequency stability [15,16,17,18]. On the other hand, power reserve control methods are developed for WPPs to provide PFR, supporting both dynamic and steady-state frequency stabilities [19,20,21,22]. However, unlike IR, PFR is provided by WPPs that are curtailed in a steady state. In other words, the available PFR from WPPs depends on the amount of curtailed power, which is determined based on system conditions such as load demand and wind speed, etc. Therefore, WPPs may not be able to provide the proper PFR whenever it is required.
To solve these problems, studies have improved WPPs operation by using energy storage systems (ESSs). These system elements provide ancillary services to enhance the power quality and the power system stability [23,24,25]. The operation of ESS is composed of charging and discharging features. The charged ESS provides additional power when disturbance such as generation loss occurs in the power system. Therefore, DGs with ESSs are able to provide frequency response to support the frequency stability. On the other hand, the discharged ESS is able to store the excessive output power from the DGs. This operation solves the mismatch between the power generation and load demand caused by renewable energy source variations. Thus, the power system stability and flexibility may be improved by installing DGs with ESSs. However, there are many technical and operational limits for ESSs. For example, there have been problems with modeling batteries used in ESSs, which causes over-charging and over-voltage problems, and this may result in causing severe explosion and fire [26,27]. Therefore, since ESSs may not provide PFR whenever required, PFR is still mainly provided by GUs, especially SGs.
As the penetration of renewable energy increases, PFR must be analyzed carefully to maintain frequency stability [28,29]. In particular, the amount of available PFR from GUs is defined with the composite system frequency response characteristic, which is called β [30]. This index is typically measured in MW/0.1 Hz, and it describes the relationship between the output power from GUs and steady-state frequency stability. As mentioned previously, as WPPs operating in the MPPT control method cannot provide PFR, the penetration of these WPPs reduces the overall β in the power system as well as fset. This problem could be relieved to a certain degree by WPPs that are able to provide PFR. However, as mentioned previously, due to the variability of renewable energy and power system conditions, WPPs may not provide adequate PFR whenever it is required.
To solve this problem, this paper proposes an algorithm to determine the operation of GUs to provide appropriate PFR. To do so, it first analyzes the impact on β of the power system caused by the high penetration of WPPs. Then, it calculates the required PFR in terms of β to restore the decreased fset. Thereafter, while considering the available PFR from WPPs, the insufficient PFR is handled by redetermining the droop coefficients of SGs governor. The major contributions of this paper are summarized as follows:
- The impact of high penetration of wind power is analyzed in terms of IR, PFR, and frequency stability.
- The algorithm for recovering the decreased fset caused by high penetration of wind power to the required boundary is proposed based on mathematical and theoretical analysis.
- The frequency stability impact of installing the planned wind power plants according to the national energy plan is analyzed on the Korean electric power system.
- The proposed method is applied to the Korean electric power system to determine the droop coefficients of SGs governor, thereby verifying its performance for improving the frequency stability.
This paper is organized as follows. Section 2 describes the operation of WPPs and the effect of penetration of wind power on frequency stability. Then, in Section 3, the details of the implementation procedure on determining the droop coefficients of SGs governor to recover the frequency stability are given with its theoretical analysis. Thereafter, Section 4 describes the characteristics of a practical Korean electric power system, and case studies are carried out to verify the effectiveness of the proposed method using the DIgSILENT PowerFactory®. Finally, conclusions and future work are presented in Section 5.
2. Effect of High Penetration of Wind Power on Frequency Stability
2.1. Operation of Wind Power Plants
The mechanical power of WPPs, Pm, for a wind speed of Vw is represented as
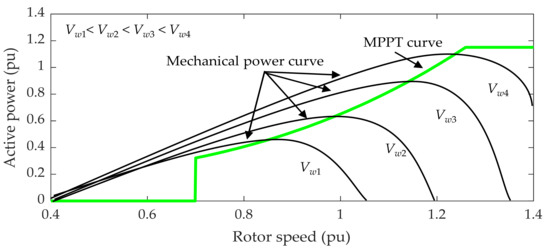
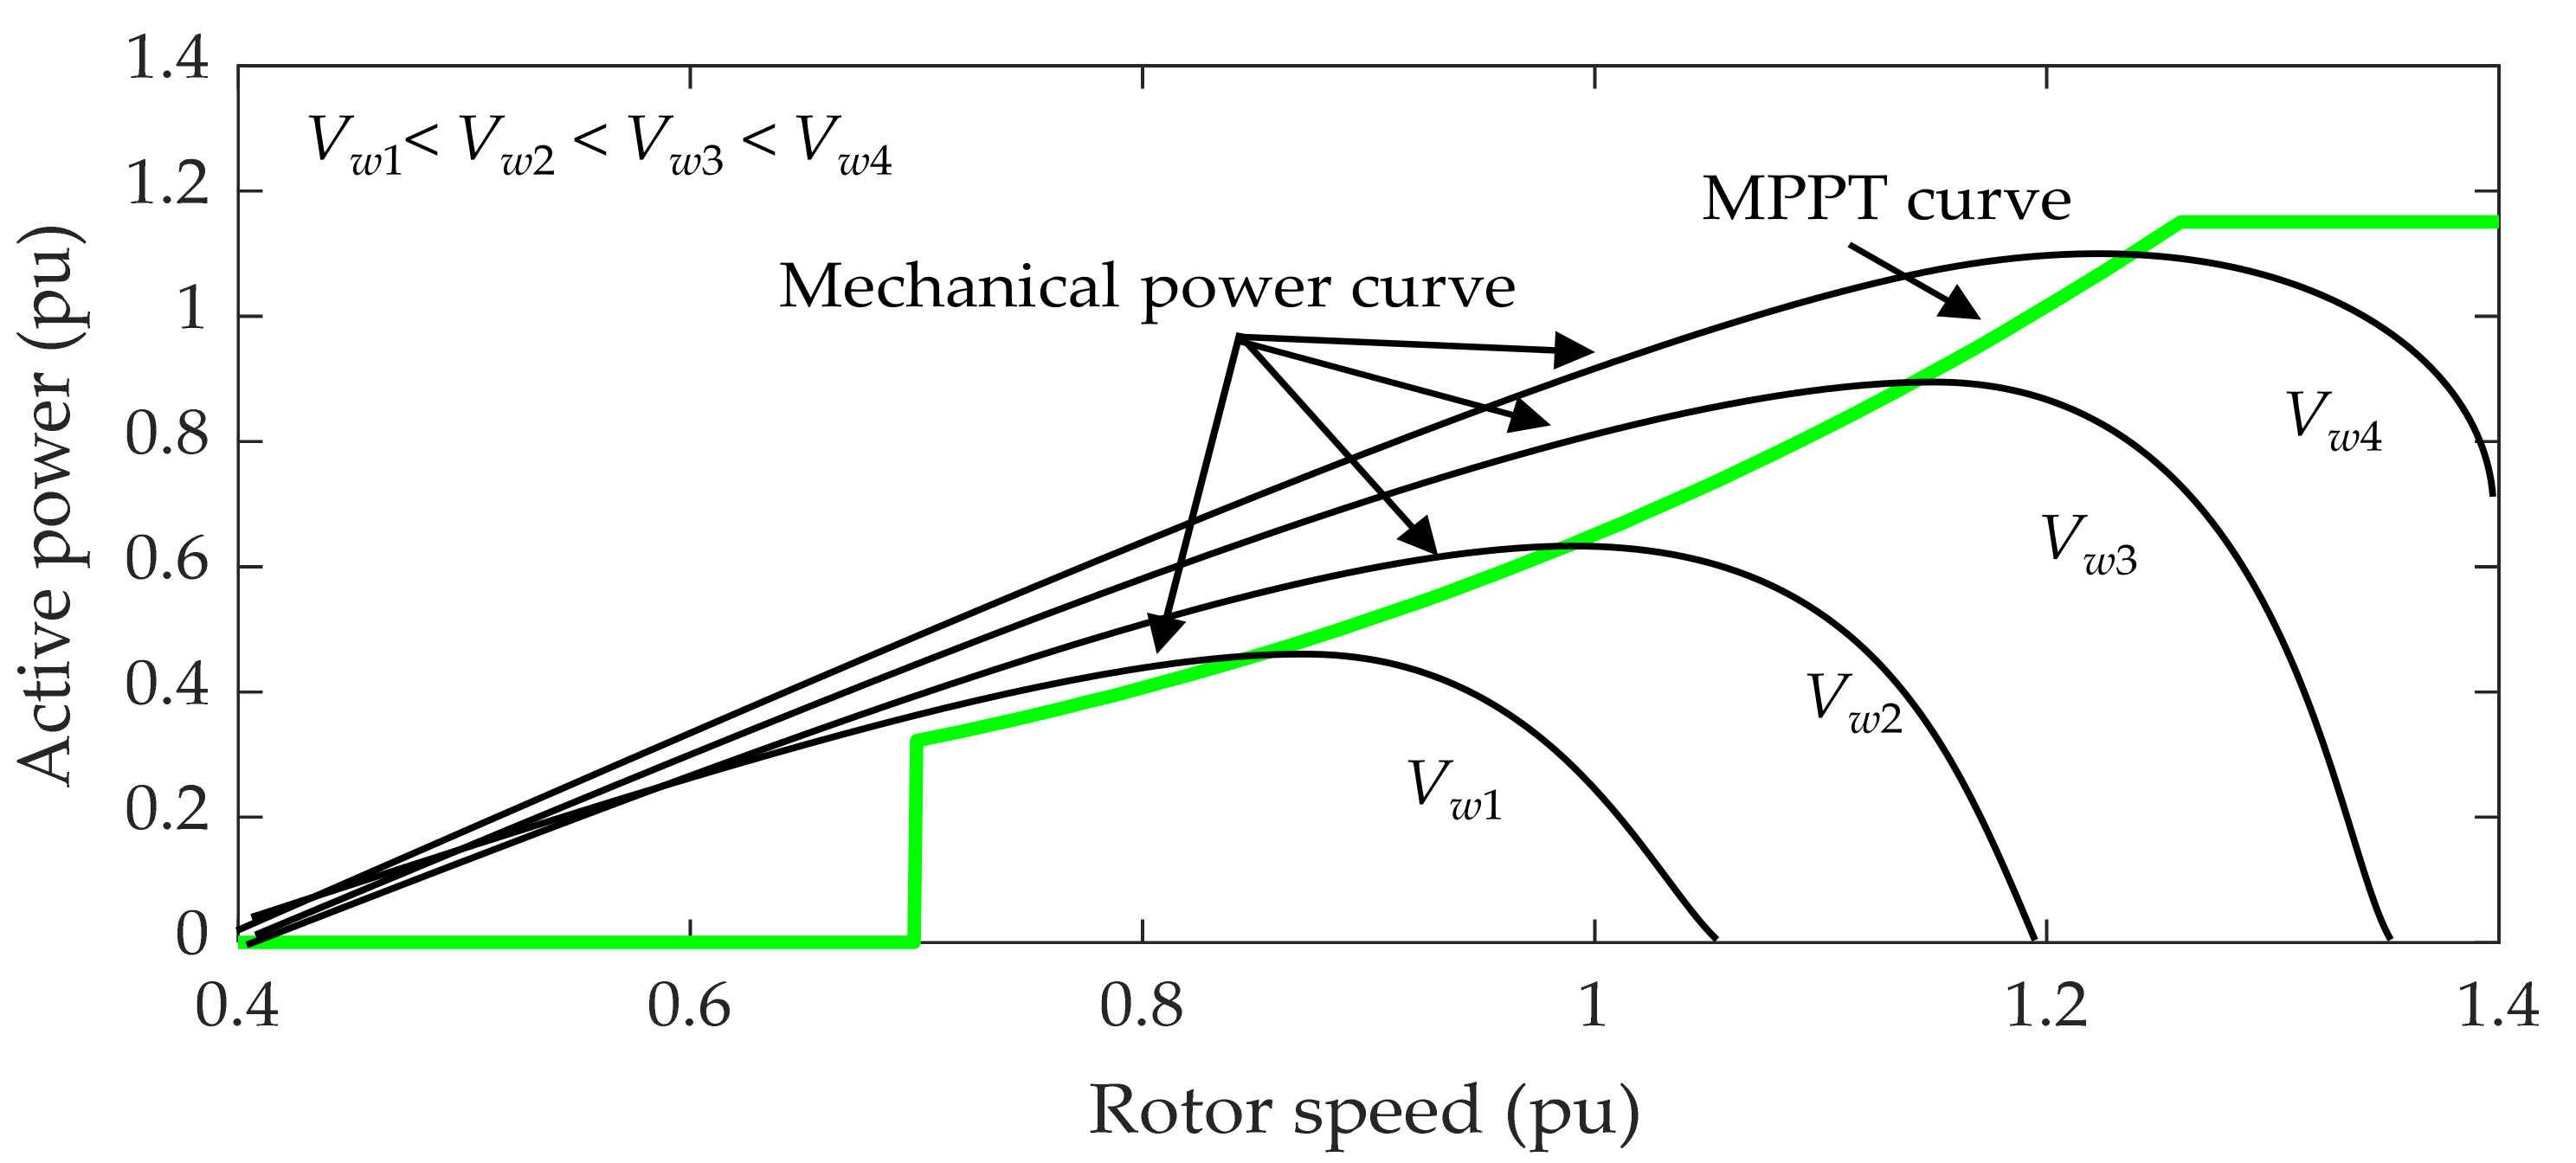
where ρ, R, cP, λ, and θ are the air density, rotor radius, power coefficient, tip speed ratio, and pitch angle, respectively. Note that ρ and R are set to 1.225 kg/m3 and 46 m, respectively, in this paper. Generally, WPPs are normally operated in the MPPT control method [8]. This is because this control method allows WPPs to provide maximum output power in a steady-state condition. Moreover, it is observed in Figure 1 that the MPPT curve intersects with the maximum value in the mechanical power curve for each Vw. Moreover, when WPPs are operated in this method, θ in (1) is maintained to 0˚, and the corresponding maximum output power, PMPPT, is determined as
where cP,max and λopt are the optimally selected value of cP and λ, respectively, by the MPPT control method, ωr is the rotor speed, and kopt is the coefficient of the MPPT curve shown in Figure 1. In this paper, cP,max, λopt, and kopt are set to 0.447, 0.501, and 7.2, respectively.
Figure 1.
Operational characteristics of the MPPT control method.
The MPPT control method is very effective since it provides maximum output power in a steady-state condition. However, when a large disturbance such as a generation trip occurs in the power system, WPPs operating in this control method cannot provide any additional power. In other words, unlike conventional SGs, they do not provide any frequency responses to compensate for the loss. Therefore, frequency stability is severely impacted as penetration of these WPPs increases.
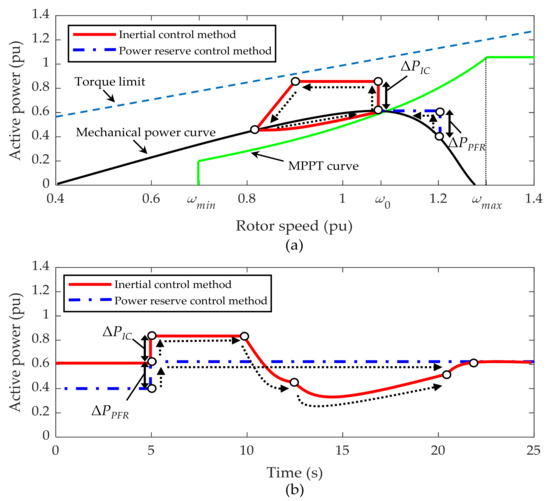
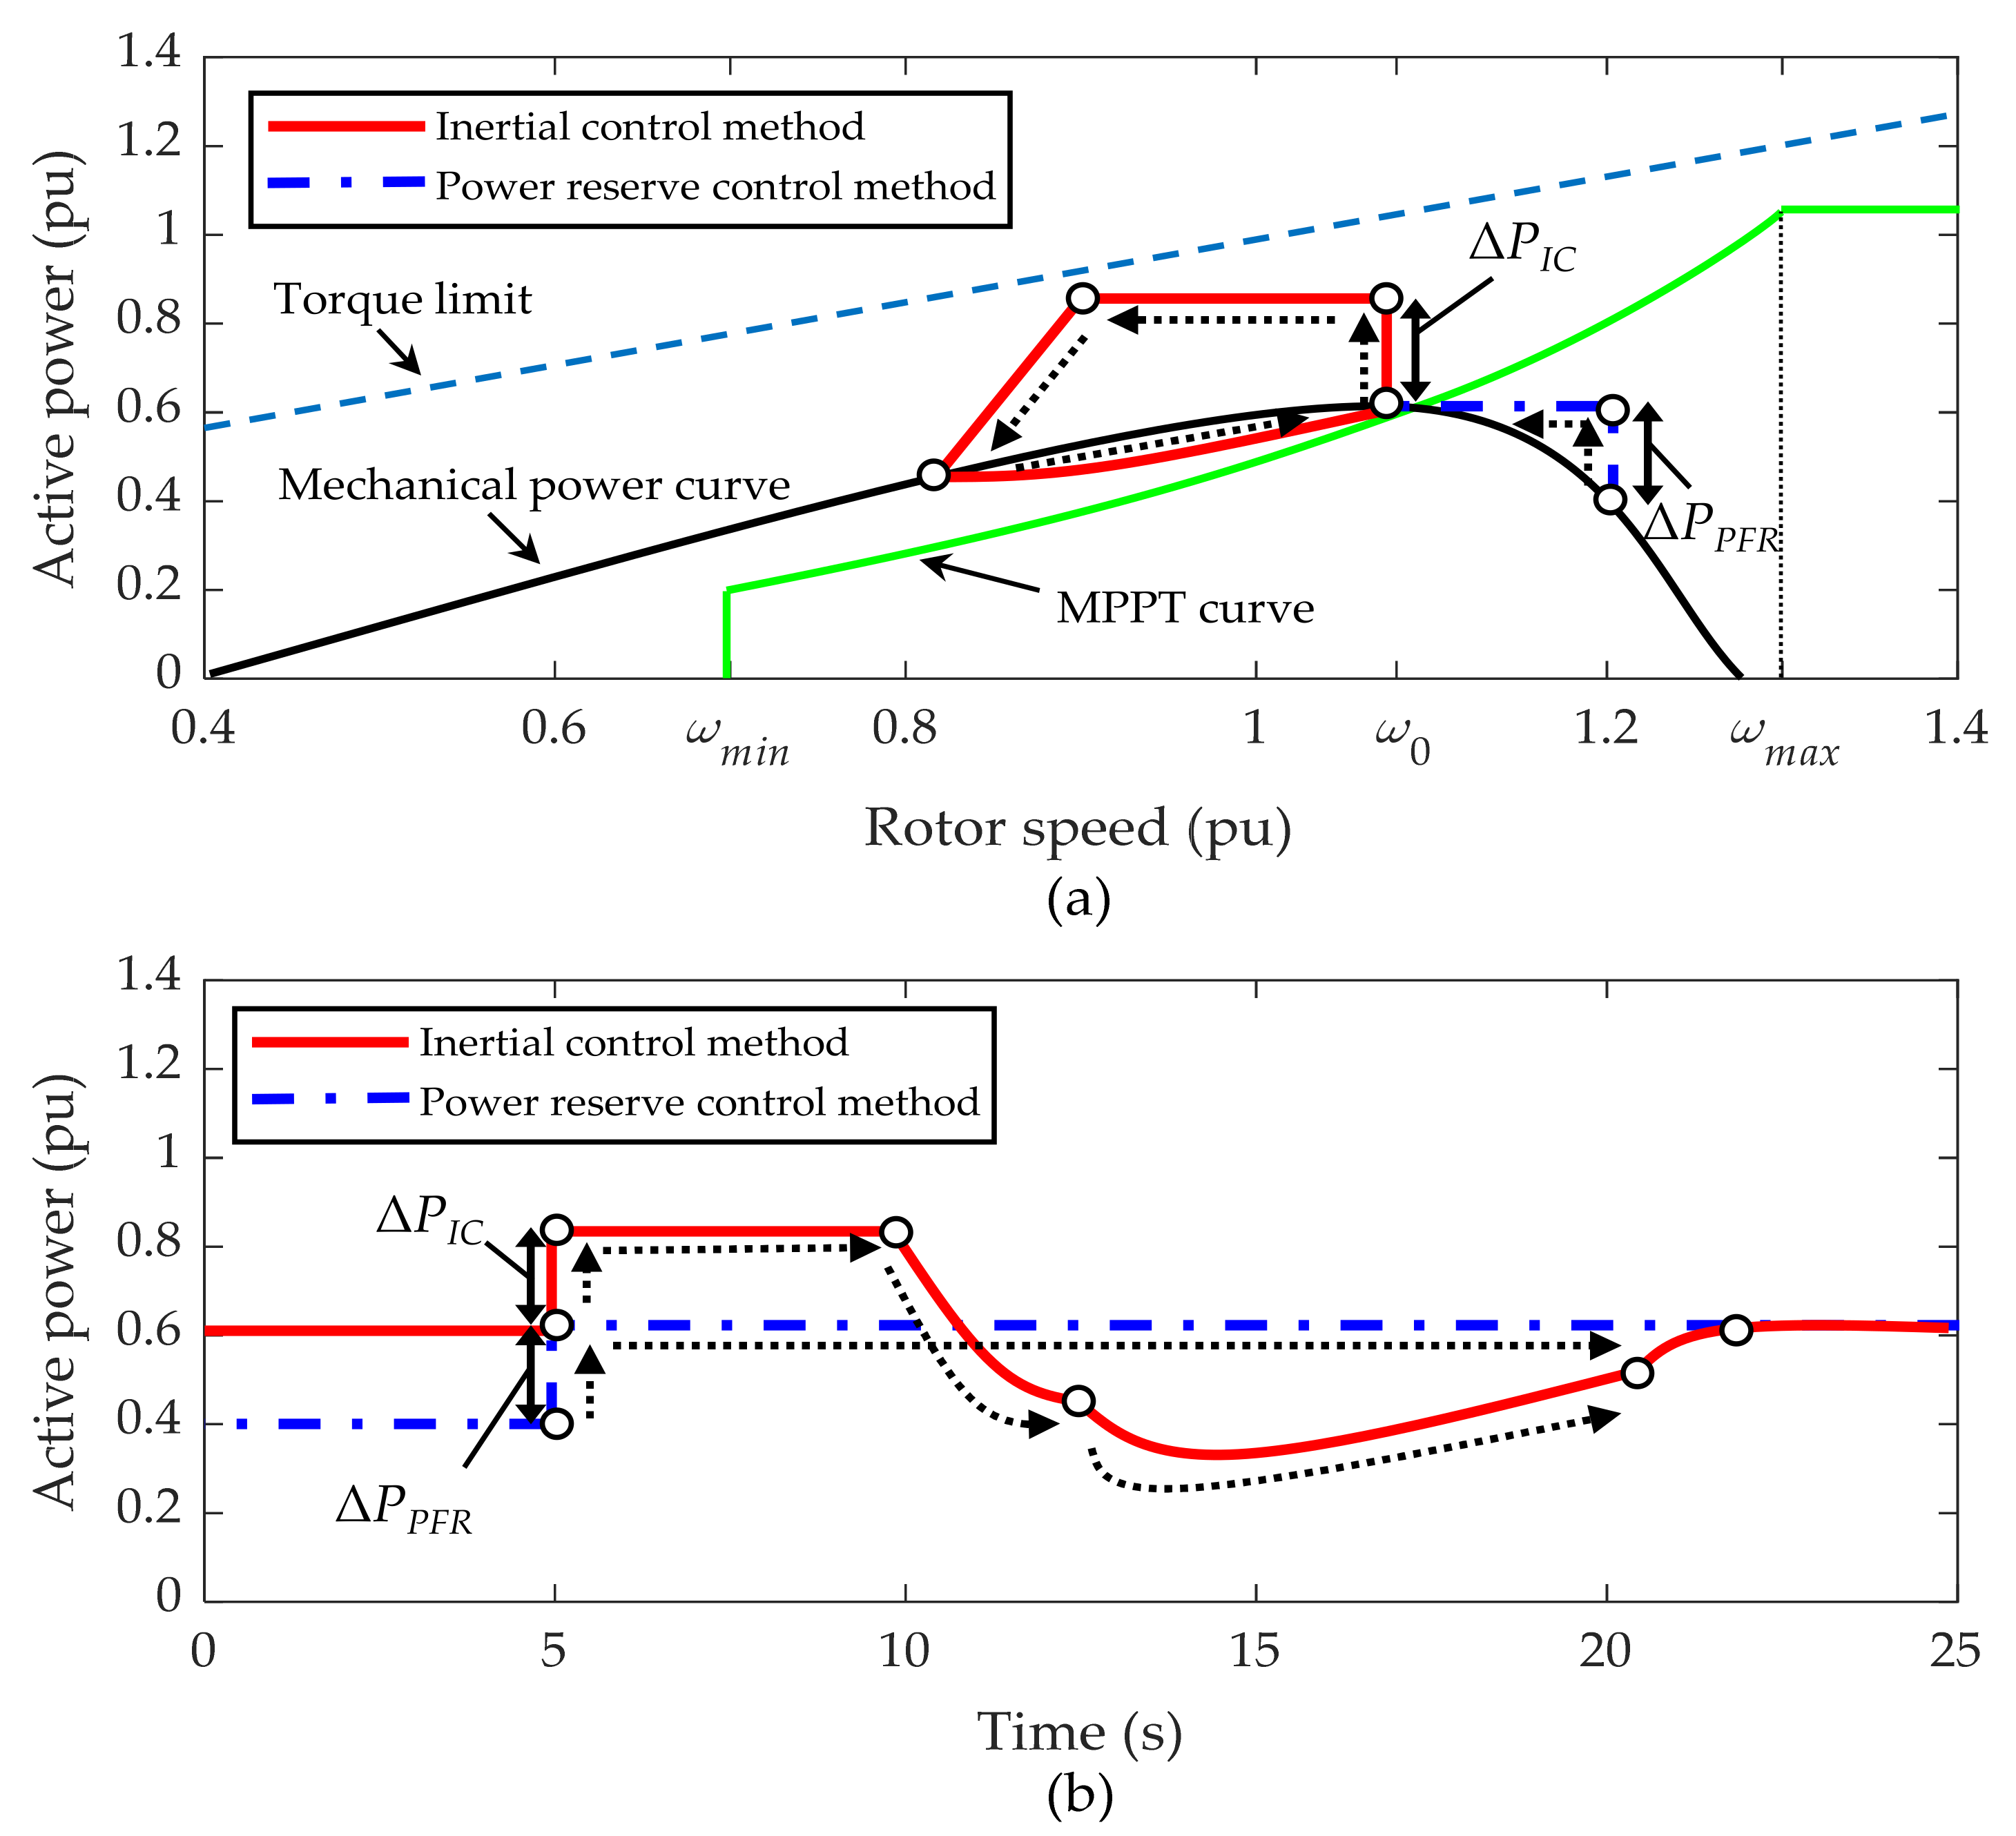
Many studies have developed inertial control methods and power reserve control methods for WPPs to provide proper frequency responses to solve this frequency stability problem. In particular, the former provides IR, which supports dynamic frequency stability, and the latter provides a power reserve, which supports both dynamic and steady-state frequency stabilities. As shown in Figure 2, WPP operating in the inertial control method increases the power by ΔPIC from the MPPT curve. After providing dynamic frequency stability support, it decreases the output power to recover its rotor speed. Thus, WPPs operating in this method provide IR during a dynamic state. Additionally, this IR is provided from releasable kinetic energy stored in the rotating mass [31], KEWPP, which is calculated as
where H is the inertia constant for WPP, ω0 is the initial rotor speed, and ωmin is the minimum speed limit.
Figure 2.
Operational characteristics of inertial control and power reserve control methods. (a) Plane of power versus rotor speed and (b) time domain.
With this releasable kinetic energy, WPPs provide IR by inertial control method [18] as
where PT-lim(ω0) is the power refers to the torque limit at ω0, P0 is the initial output power from the WPPs before providing the IR, and n is the parameter to prevent excessive power increment. On the other hand, WPPs operating on the power reserve control method may increase the output power by increasing the output power from curtailed power, as shown in Figure 2. Therefore, unlike the inertial control method, this method maintains the increased power, ΔPPFR. Thus, WPPs operating in this method provide PFR and support both dynamic and steady-state frequency stabilities.
2.2. Frequency Stability Analysis Based on Penetration of Wind Power
When a large disturbance such as a generation trip occurs in the power system, SGs provide frequency responses to secure the frequency stability. In particular, the relationship between fset and PFR provided from SGs can be analyzed by composite system frequency response characteristic [30], β, which is calculated as
where Ri, Si, and PFi are the droop coefficient, power capacity, and power factor of i-th SG, respectively, and fnorm is the nominal value of frequency. By using β, fset can be calculated as
where Ploss is the size of generation loss, and DB is the dead-band of the governor. Therefore, this indicates that even for the same size of generation loss, fset decreases further in the power system with smaller β.
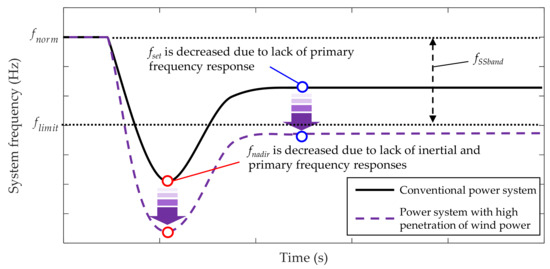
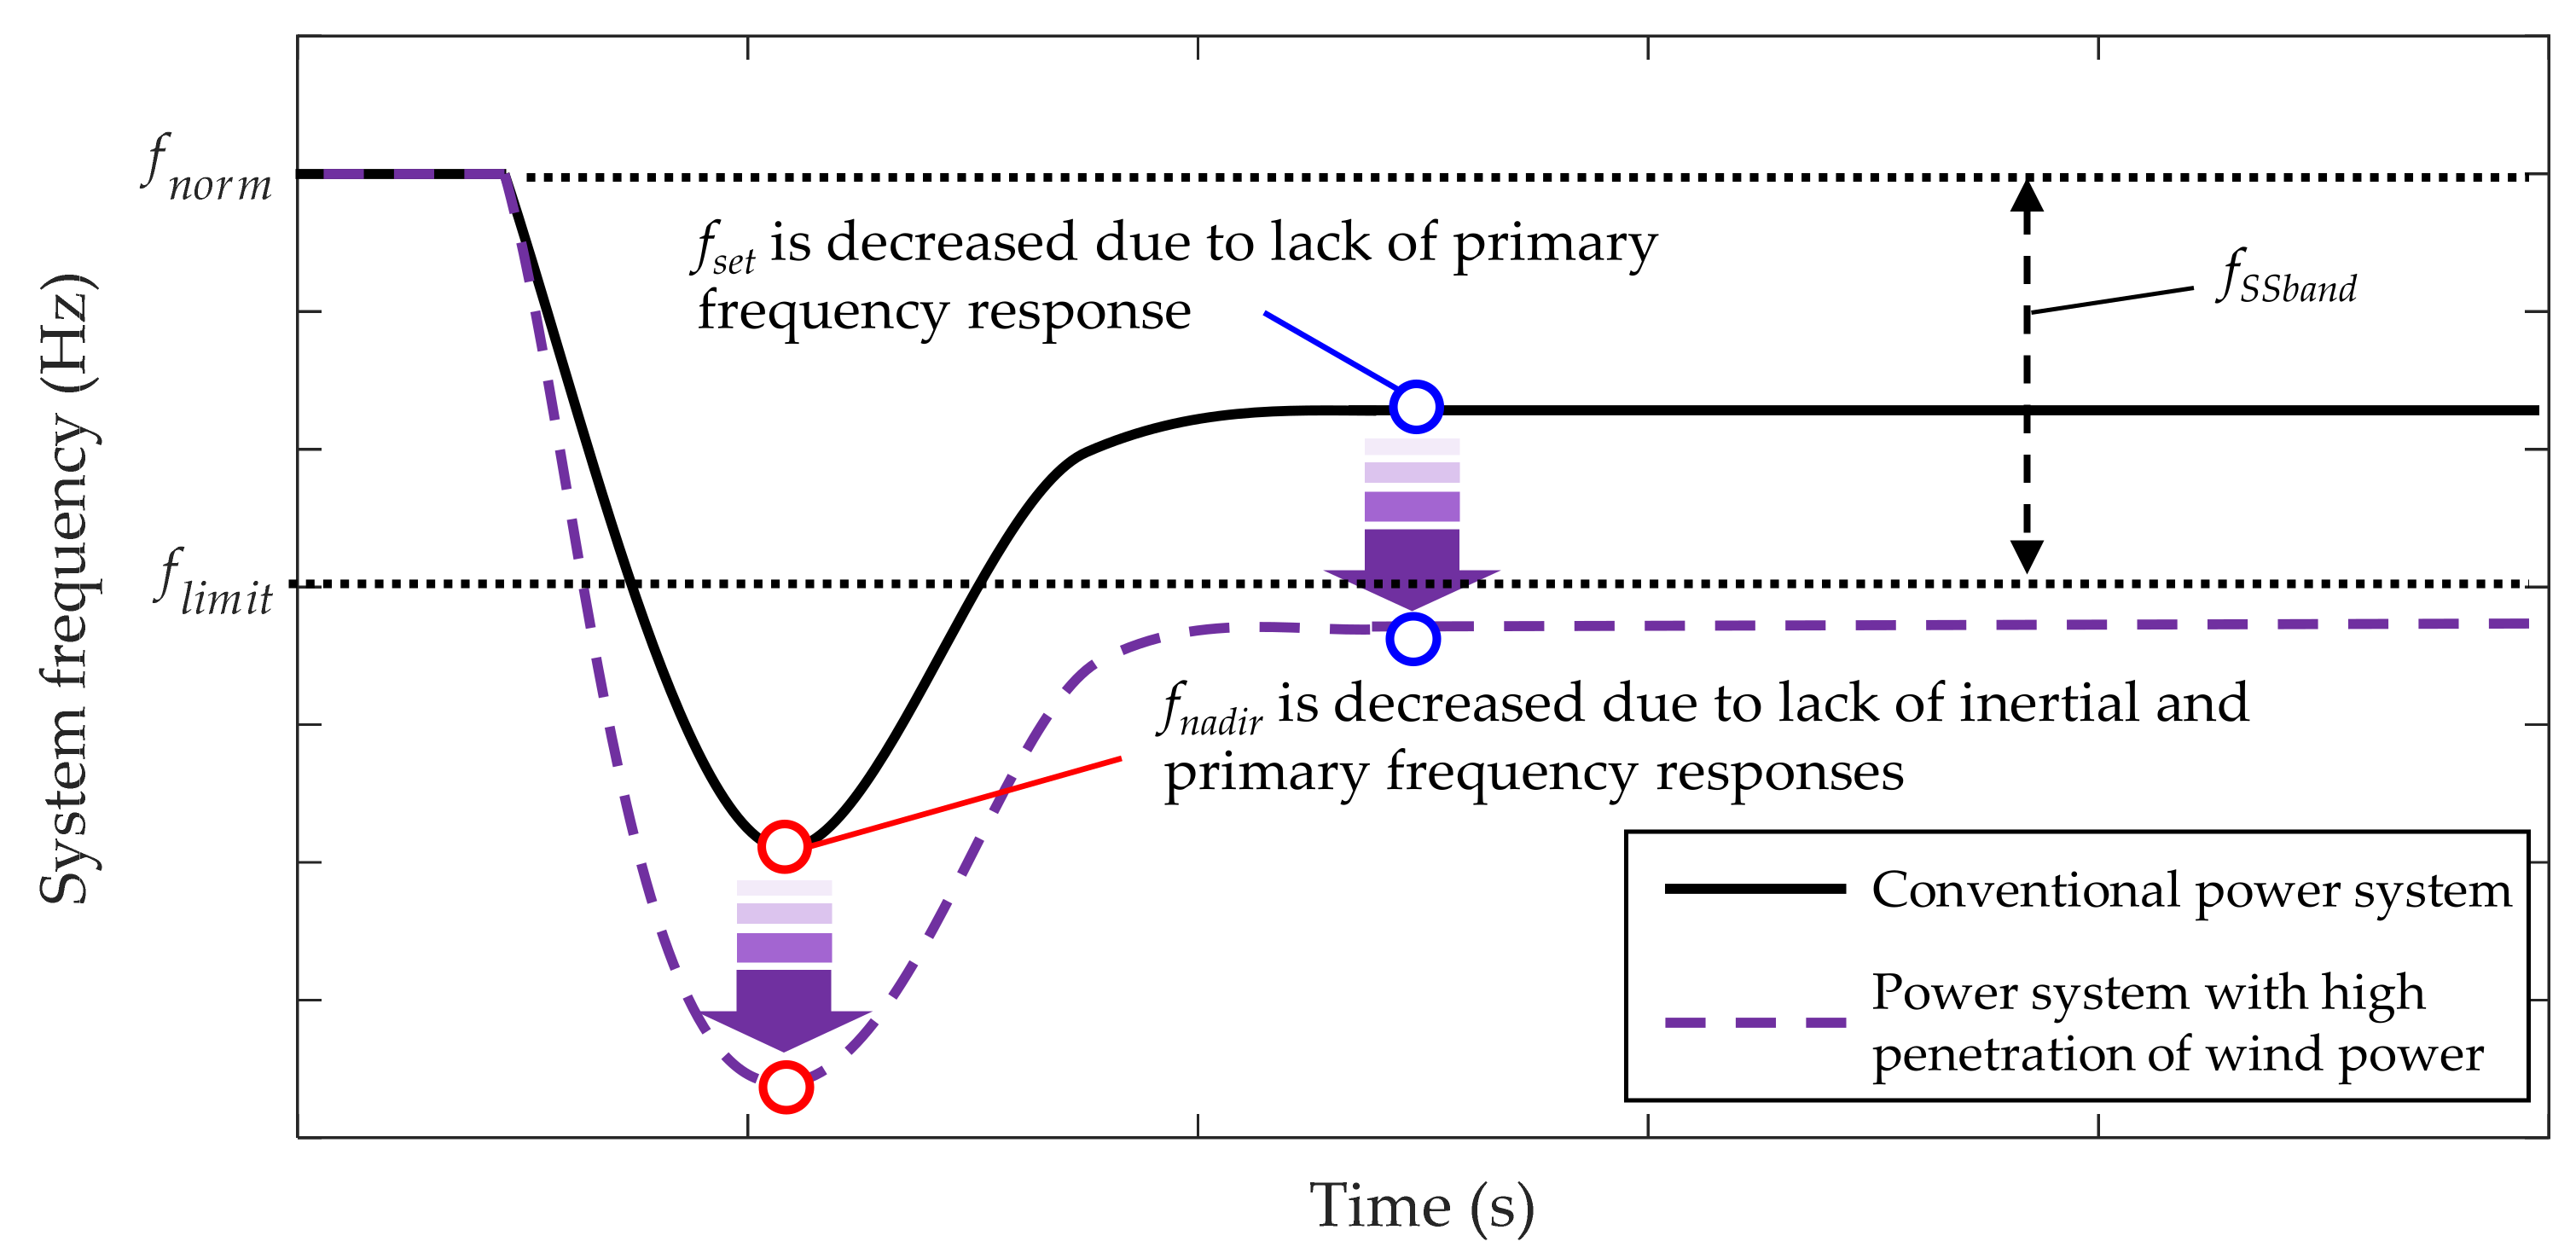
As shown in Figure 3, the decrease in system inertia and power reserve due to penetration of wind power causes adverse impacts on both dynamic and steady-state frequency stabilities. In addition, as mentioned previously, the former is improved by both IR and PFR, and the latter is improved by PFR. Moreover, while IR is provided from the releasable kinetic energy stored in the rotating mass of WPP, PFR is provided from WPPs that were previously curtailed. In other words, in order to provide PFR by WPPs, they need to be curtailed first. Therefore, the amount of PFR may not be sufficient depending on power system conditions such as wind speed and load demand. Thus, PFR must be determined appropriately for other GUs to provide sufficient frequency support. Of note, lack of PFR may decrease the fset below the frequency deviation limit (flimit), which may prevent AGC operation that restores the fset to fnorm. Thus, it is important for system operators to store proper power reserve to provide sufficient PFR.
Figure 3.
The effect of wind power penetration on frequency stability.
3. Proposed Droop Coefficients Determination Method
As mentioned above, the high penetration of wind power causes a severe impact on the frequency stability, which may prevent the operation of AGC and cause under-frequency load shedding relay. Therefore, the system operator must take appropriate action on the GUs to maintain frequency stability. Unfortunately, in the authors’ opinion, there is only a standard on the overall amount of power reserve [32,33], but no decision-making scheme or other standards on determining the operation of GUs to store sufficient PFR after high penetration of renewable energy.
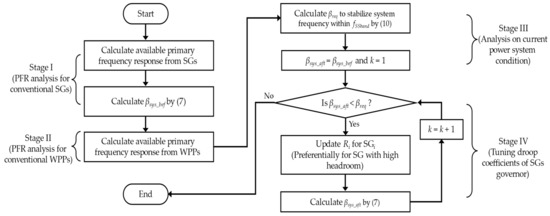
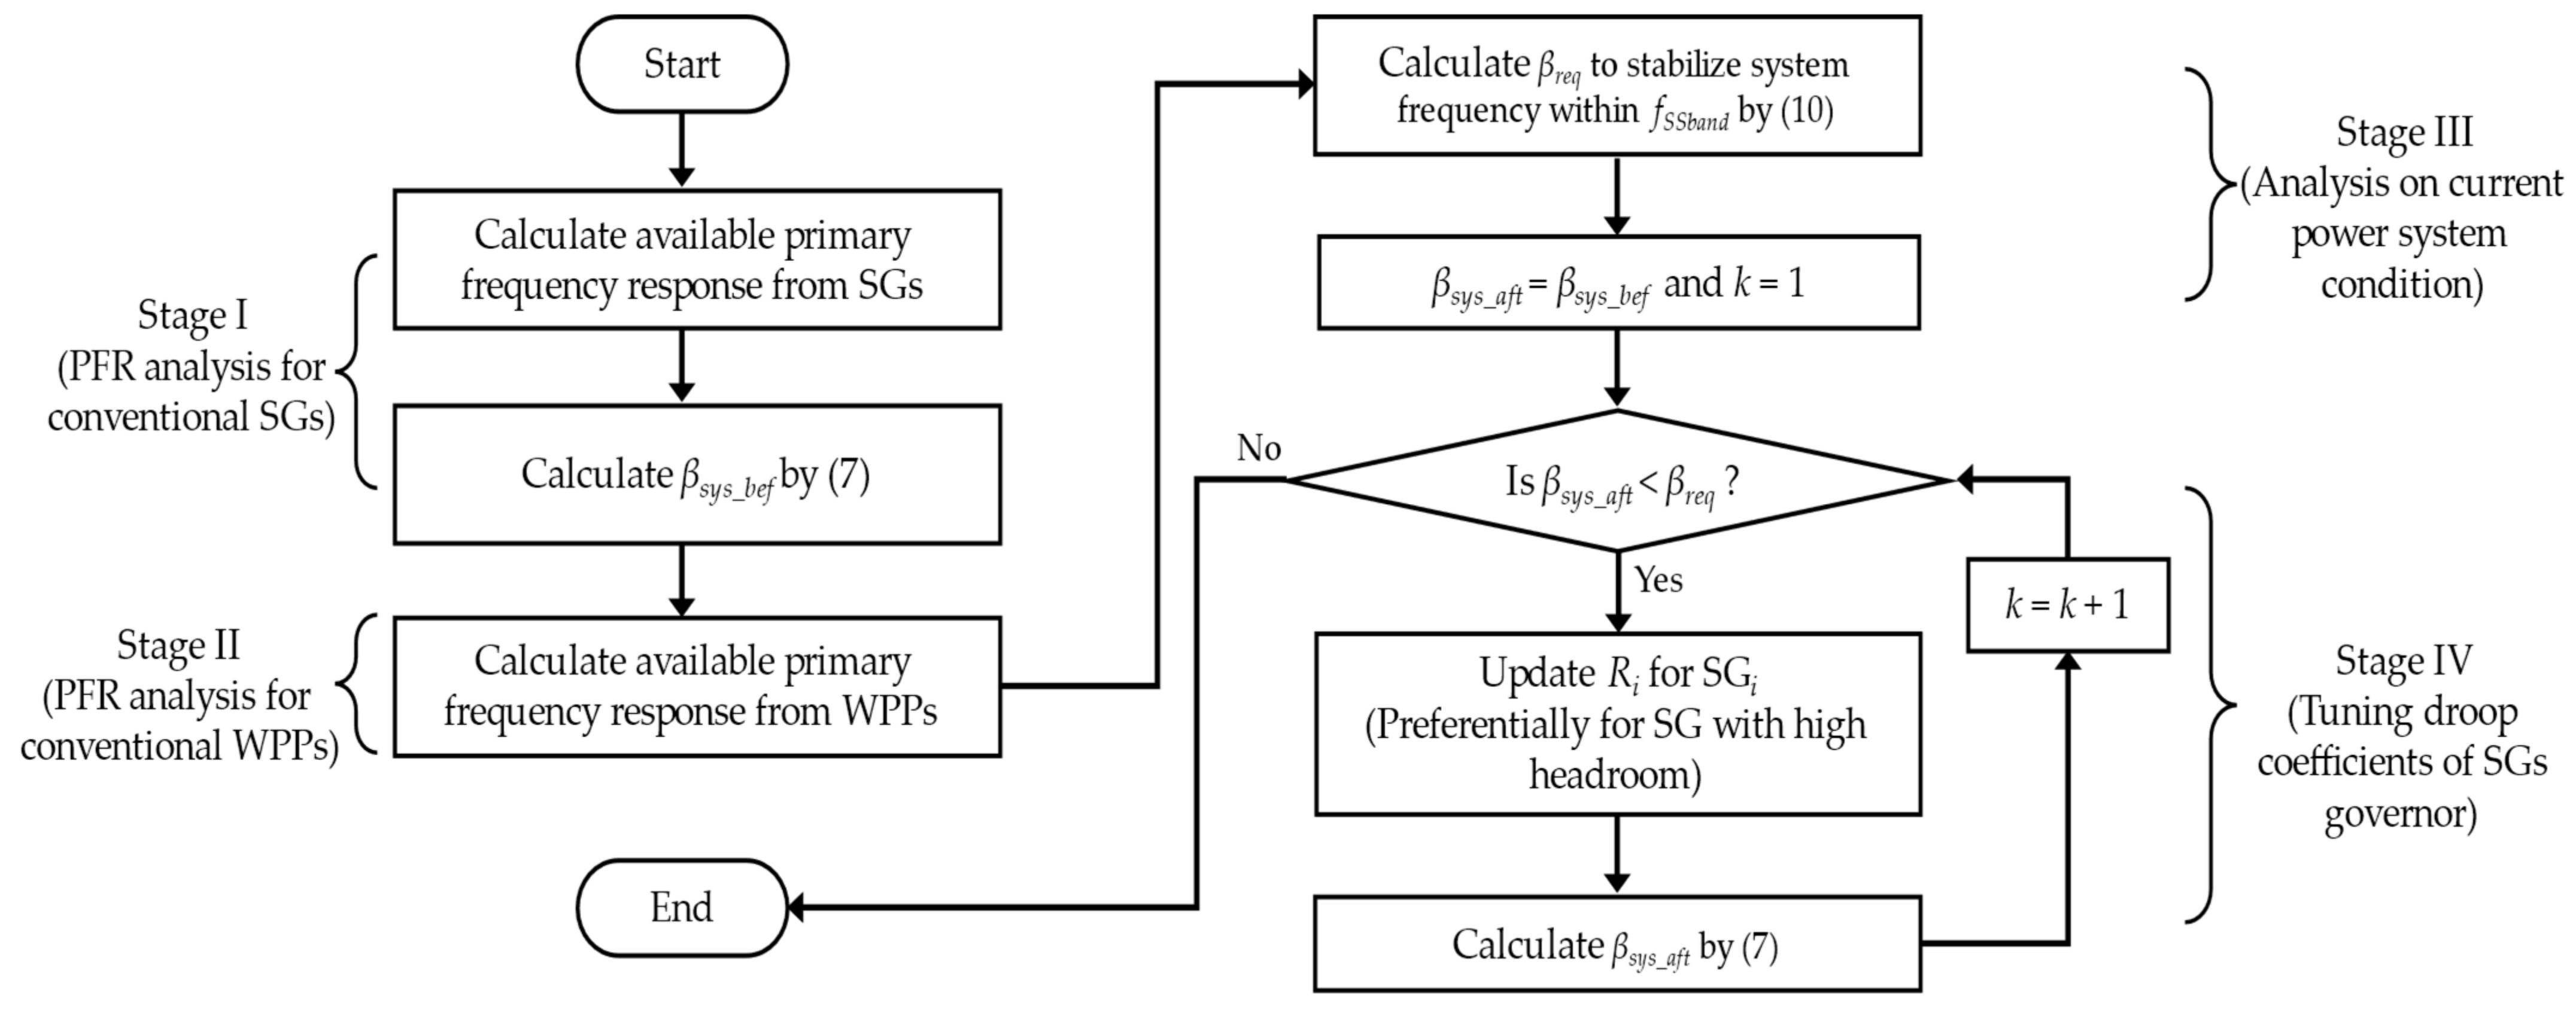
In order to raise the fset, which is decreased by high penetration of wind power, to flimit, the proposed algorithm redetermines the droop coefficient of SGs governor while considering the allowable PFR from WPPs. To do so, the proposed method calculates the required PFR to restore the frequency stability. Then, the available PFR stored in both SGs and DGs are calculated to determine whether the power system has sufficient or insufficient PFR to satisfy its required value. Thereafter, if the power system has insufficient PFR to stabilize the frequency within the required boundary, the droop coefficients of SGs governor are newly determined to increase PFR to that of the required value. The overall procedure to implement the proposed droop coefficients determination method is shown in Figure 4. Moreover, the detailed operations in four stages to implement the proposed algorithm are explained below.
Figure 4.
Overall procedure to determine the droop coefficients.
- Stage I—PFR analysis for conventional SGs
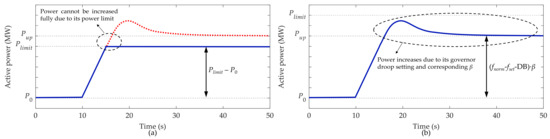
In the early stage of the proposed algorithm, the available PFR from the remaining conventional SGs is analyzed. As SGs provide PFR through the governor, only the SGs equipped with the governor are considered. However, as shown in Figure 5, even though the SG is able to increase the power according to its governor droop coefficient setting, it may not provide PFR fully due to its power limit. Therefore, the overall available PFR from conventional SGs in a power system, βsys, is calculated as
where Pup,i and Plimit,i are the increased power by PFR and maximum power limit of i-th SG, respectively. Unlike IR, PFR from SG is only provided when the frequency is beyond the DB. In particular, the DB in the Korean electric power system is 0.036 Hz. Therefore, in this stage, βsys_bef, which is β calculated before redetermining droop coefficients, is calculated by (7).
Figure 5.
Primary frequency response from SG. (a) Limited by power limit, (b) PFR provided according to its governor droop coefficient setting.
- 2.
- Stage II—PFR analysis for WPPs
In this stage, available PFR from WPPs is calculated. Unlike SGs, since WPPs are normally operated by the MPPT control method, they do not store power reserve. Therefore, these WPPs cannot provide PFR when a disturbance occurs in a power system. However, as mentioned previously, due to the increasing penetration of wind power, they are forced by the system operator to curtail a certain amount of power. Then, these WPPs store power reserve, which can provide PFR when a disturbance occurs in a power system. Moreover, the available PFR from overall WPPs, PFRWPP, is calculated as
- 3.
- Stage III—Analysis on required β
In this stage, the power system condition is analyzed based on β to ensure that the system has sufficient PFR to raise the fset to flimit. Therefore, the required β to stabilize the frequency within the frequency deviation limit band (fSSband) caused by disturbance with a power loss of Ploss is calculated as
where βreq is the required β for the system frequency to be stabilized within fSSband considering the available PFR from WPPs. Then, βsys_bef is compared with βreq before tuning the droop coefficient of SGs governor. If βsys_bef is higher than βreq, this indicates that the power system has enough power reserve, and the PFR can stabilize the frequency within fSSband. On the other hand, if βsys_bef is smaller than βreq, this indicates that the frequency cannot converge within fSSband. Therefore, the system operator must increase the available PFR for the power system.
However, unless WPPs are equipped with an energy storage system, they cannot provide additional PFR other than the previously curtailed power. Therefore, the system operator must increase the available PFR by tuning the droop coefficients of SGs governor.
- 4.
- Stage IV—Tuning droop coefficients of SGs governor
In the last stage, droop coefficients of SGs governor are redetermined to increase the βsys_bef to βreq. To do so, β for SG with high headroom is preferentially increased. This iteration is repeated until the βsys_aft, which is β calculated from the redetermined droop coefficients, is higher than βreq. As the result, the frequency can be stabilized within the fSSband. Note that the available ranges for droop coefficients vary according to the type of the turbine governors [34].
4. Simulation Results
4.1. Characteristics of Korean Electric Power System
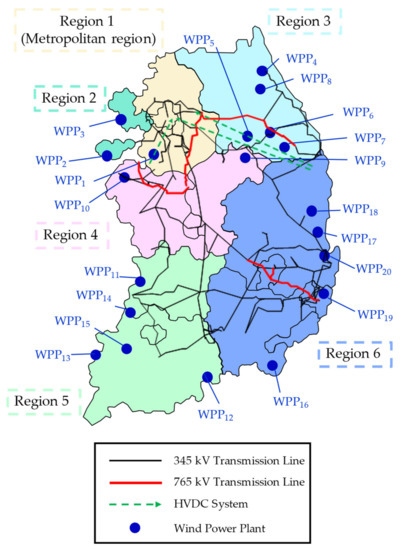
To evaluate the performance of the proposed method, case studies were carried out on the practical Korean electric power system. In this power system, there are more than 400 SGs with a total power capacity of 145 GW. Moreover, as shown in Figure 6, there are six regions in the Korean electric power system according to provinces. Note that simulations were carried out based on one day during winter in 2020. On this particular day, the characteristics of each region, including power generation of SGs, load demand, H, β, and S, are given in Table 1. It is observed that Region 1 has a large load demand compared to its power generation. This is because Region 1 is the metropolitan region, including the capital Seoul. Therefore, insufficient power is transmitted from other regions through high voltage transmission lines and high-voltage direct-current (HVDC) system.
Figure 6.
Korean electric power system with high penetration of WPPs.
Table 1.
Conventional SGs characteristics in Korean electric power system.
Moreover, the Korean government has announced the “Renewable Energy 3020 Action Plan” to increase the hosting capacity of renewable energies, which includes installing WPPs with a total capacity of 17.7 GW until 2030 [1,2]. Therefore, in this paper, among planned WPPs based on the national energy plan, 20 WPPs given in Table 2 with a total capacity of 11 GW are applied in the current Korean electric power system, as shown in Figure 6.
Table 2.
WPPs characteristics in Korean electric power system.
4.2. Simulation Results Based on Proposed Droop Coefficients Determination Method—Case Study 1: WPPs with Power Reserve
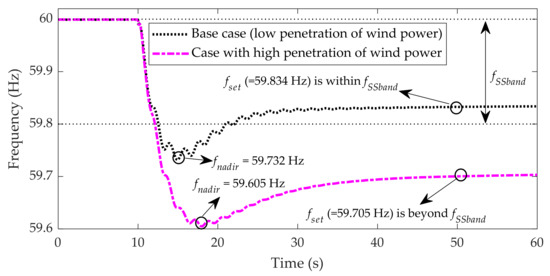
To analyze the frequency stability, the Shinkori nuclear power plant with a capacity of 1600 MW in Area 6, which is one of the largest SG in the Korean electric power system, was suddenly disconnected at 10 s. As many WPPs (total of 11 GW) penetrated the Korean electric power system, the conventional SGs were correspondingly replaced. As the result, βsys_bef decreased from 1255 MW/0.1 Hz to 621 MW/0.1 Hz. Then, with the Ploss of 1500, the fset reduced from 59.834 Hz to 59.705 Hz by (6), which is beyond the fSSband (see Figure 7). Note that since there are about 2000 buses in the power system, the frequency cannot be analyzed for every bus. Therefore, system frequency is calculated based on the center of inertia [35]. Moreover, WPPs from WPP1 to WPP11 curtailed to a total of 371 MW to balance the power supply and load demand. WPPs from WPP1 to WPP10 curtailed by 10%, and WPP11 curtailed by 7%. Therefore, these WPPs are able to provide a power reserve total of 371 MW. On the other hand, WPPs from WPP12 to WPP20 are operated in MPPT operation point.
Figure 7.
Effect of wind power penetration on system frequency in Korean electric power system.
In order to recover the fset within the fSSband, the proposed method of Figure 4 was applied. In Stage I, the value of βsys_bef was calculated as 621 MW/0.1 Hz for remaining conventional SGs by (7). Next, in Stage II, considering the current wind speed and the curtailed power, the available PFR from 20 WPPs were calculated by (9). In this case, the curtailed WPPs from WPP1 to WPP11 were available to provide a PFR total of 371 MW. Thereafter, in Stage III, βreq was calculated for the current condition in the power system. Note that the fSSband is 0.2 Hz for the Korean electric power system, and for the case when the Shinkori nuclear power plant was tripped out, the value of Ploss was 1500 MW. However, as WPPs were available to provide PFR of 371 MW, the size of Ploss decreased to 1129 MW. As the result, βreq was calculated as 688 MW/0.1 Hz by (10). Since βsys_bef, which is 621 MW/0.1 Hz, is lower than the βreq, the fset cannot be stabilized within fSSband. Therefore, in Stage IV, the Ri was tuned for SGi to increase the βsys_aft to that of βreq.
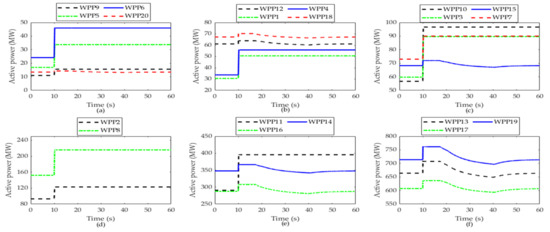
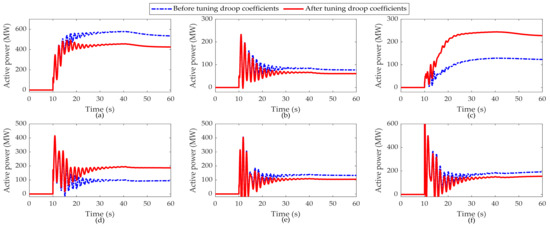
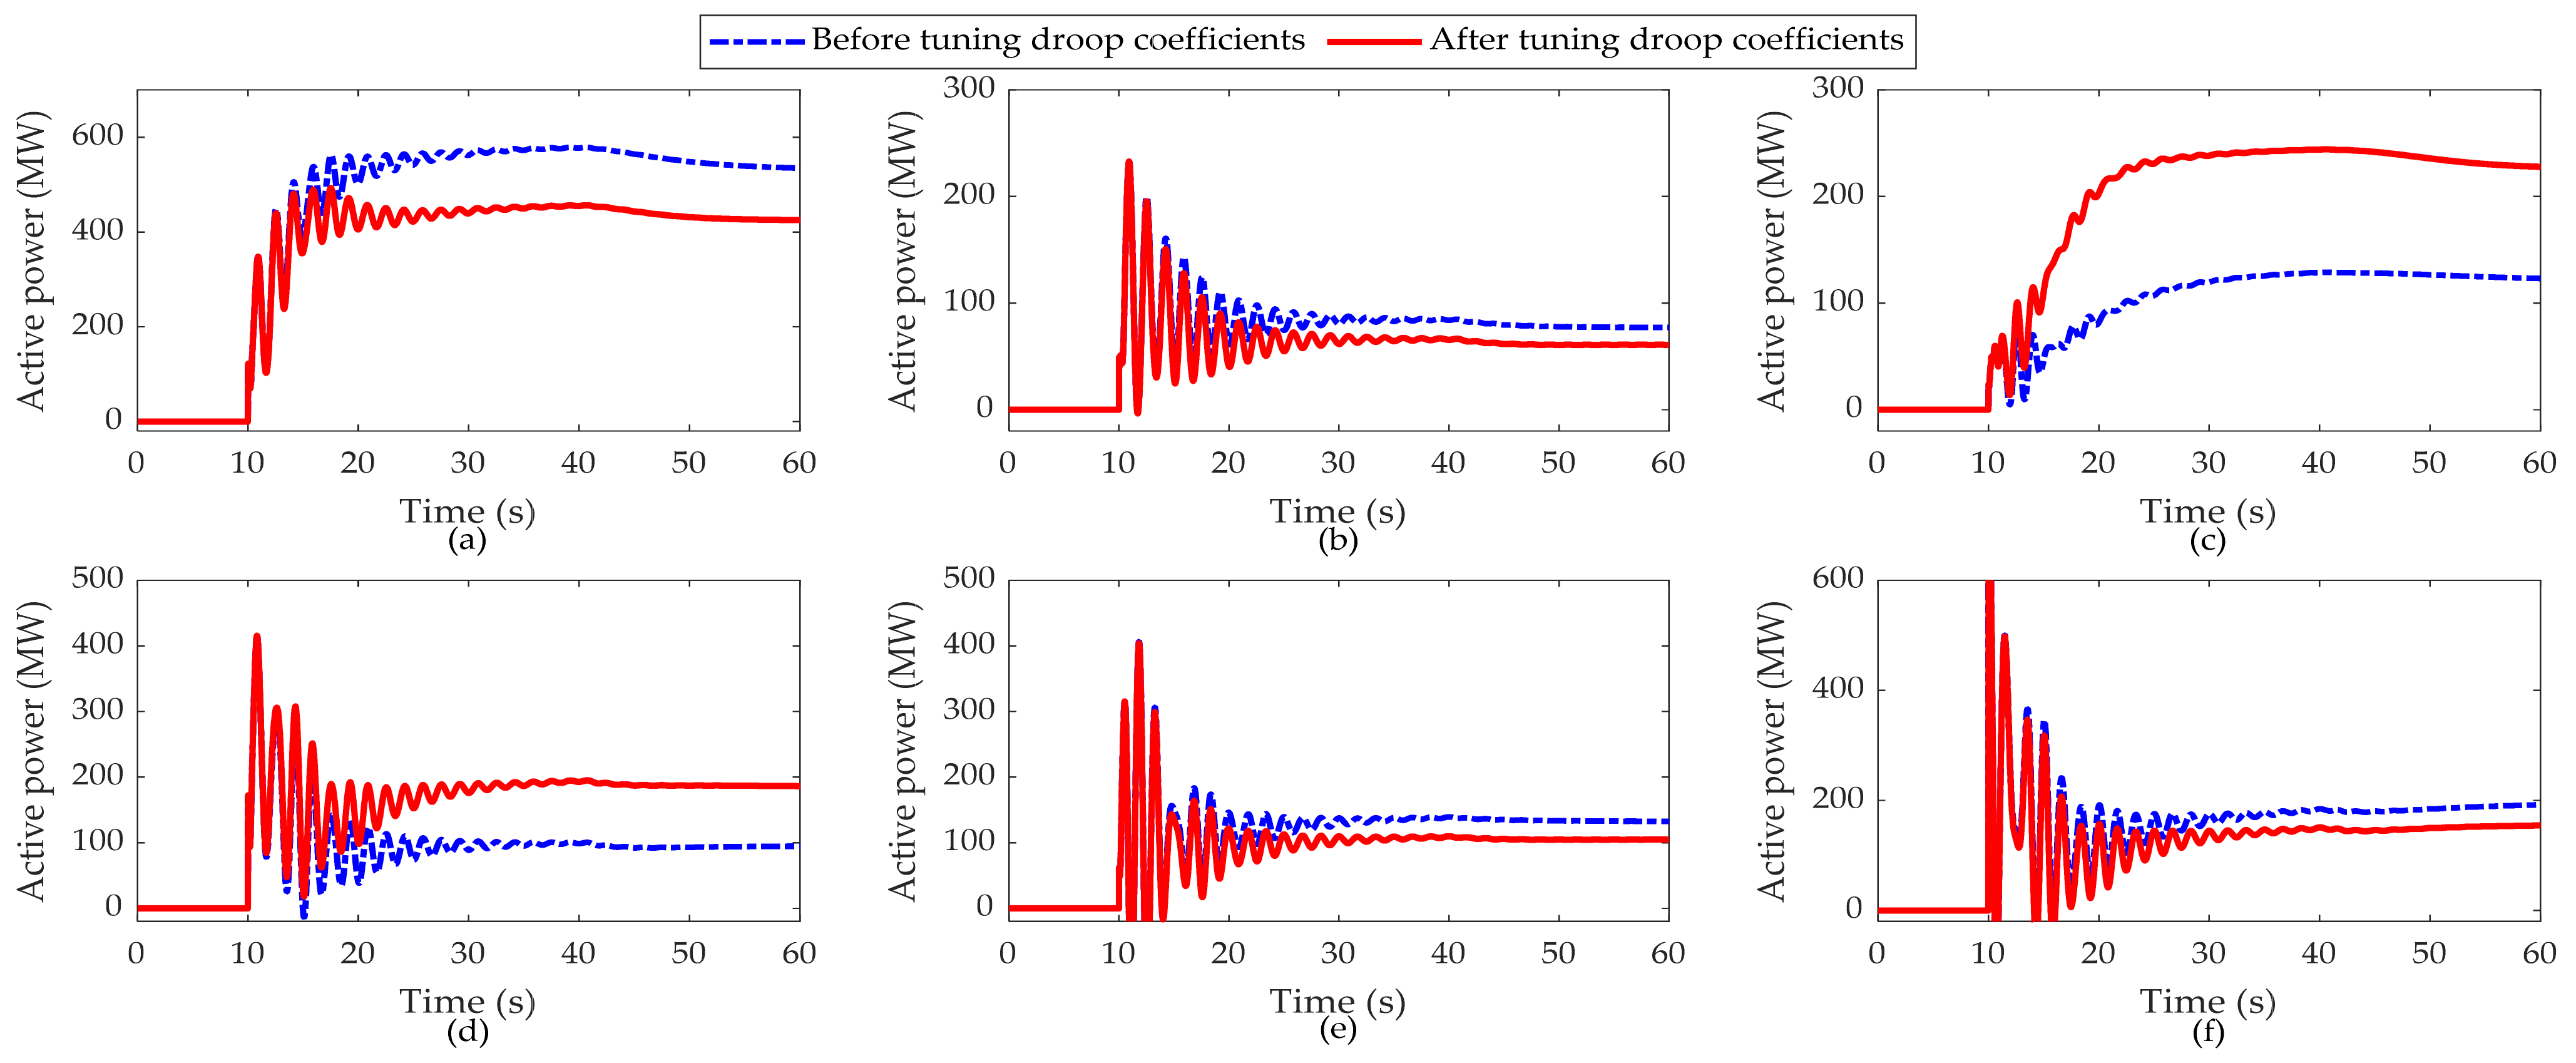
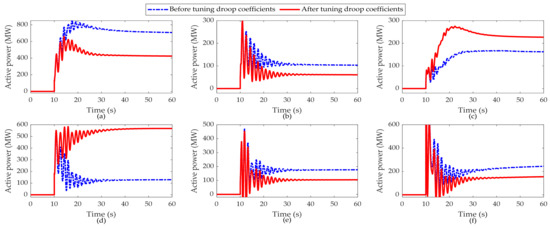
As Shinkori nuclear power plant was suddenly disconnected at 10 s, the curtailed WPPs (from WPP1 to WPP11) provided PFR, and the other WPPs (from WPP12 to WPP20) provided IR, as shown in Figure 8. On the other hand, as shown in Figure 9, it is observed that the PFR of the SGs has become different since the SGs governor droop coefficient was redetermined to raise the βsys_aft to βreq. In particular, after tuning the droop coefficient of SGs governor, the PFR in Regions 3 and 4 increased while the PFR in other regions decreased. This indicates that SGs in Regions 3 and 4 had a higher headroom compared to other regions. However, the total amount of PFR provided is the same for both cases. This is because the value of Ploss is the same for these cases.
Figure 8.
Output power from each WPP for case study 1. (a) WPP5, WPP6, WPP9, WPP20, (b) WPP1, WPP4, WPP12, WPP18, (c) WPP3, WPP7, WPP10, WPP15, (d) WPP2, WPP8, (e) WPP11, WPP14, WPP16, and (f) WPP13, WPP17, WPP19.
Figure 9.
Total output power from SGs for case study 1. (a) Region 1, (b) Region 2, (c) Region 3, (d) Region 4, (e) Region 5, and (f) Region 6.
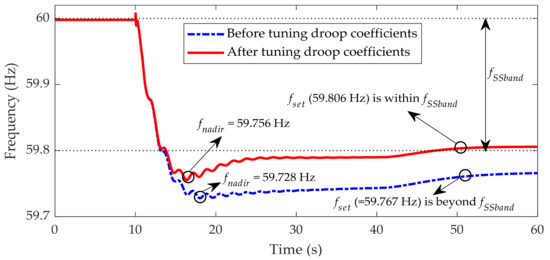
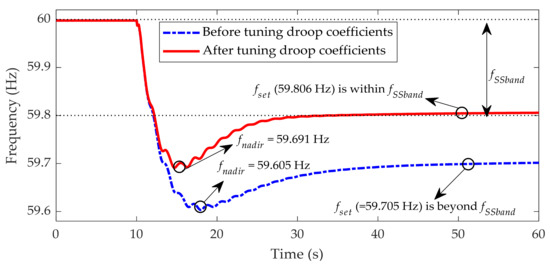
Moreover, the system frequency for the two cases is shown in Figure 10. It is observed that fnadir and fset of both cases are increased more than the case with high penetration of wind power (indicated by the magenta dash-dotted line in Figure 7). This is because WPPs (from WPP1 to WPP11) provide IR to support the dynamic frequency stability, and the other WPPs (from WPP12 to WPP20) provide PFR to support both dynamic and steady-state frequency stabilities. However, it is also observed that fset is not stabilized within fSSband (indicated by the blue dash-dotted line in Figure 10) for the case before tuning the droop coefficients. This indicates that WPPs cannot provide sufficient PFR from current wind conditions, and the SGs cannot also provide sufficient PFR with current droop coefficients. On the other hand, increasing the βsys_aft to βreq for the case after tuning the droop coefficients shows that the fset is successfully raised within the fSSband (indicated by the solid red line in Figure 10). In particular, compared to the case before tuning the droop coefficients, fnadir and fset are raised by 0.028 Hz and 0.039 Hz, respectively.
Figure 10.
Results of system frequency for case study 1.
4.3. Simulation Results Based on Proposed Droop Coefficients Determination Method—Case Study 2: WPPs without Power Reserve
Even though various power reserve control methods have been developed for WPPs in recent studies, due to the technical and operational limits, WPPs may not provide power reserve or inertial response whenever it is required. Therefore, case study 2 assumes that WPPs do not provide any frequency responses. Thus, different from case study 1, WPPs maintain the output power when a disturbance occurs at 10 s. To analyze and solve the insufficient PFR for this case, the proposed method of Figure 4 was applied. In Stages I and III, while βsys_bef is the same as that in case study 1, βreq was increased from 688 MW/0.1 Hz to 915 MW/0.1 Hz compared to case study 1. This is because WPPs do not provide PFR to compensate for the loss in (10). Thus, the difference between βreq and βsys_bef was increased for this case study. In other words, the PFR is much more insufficient for the power system.
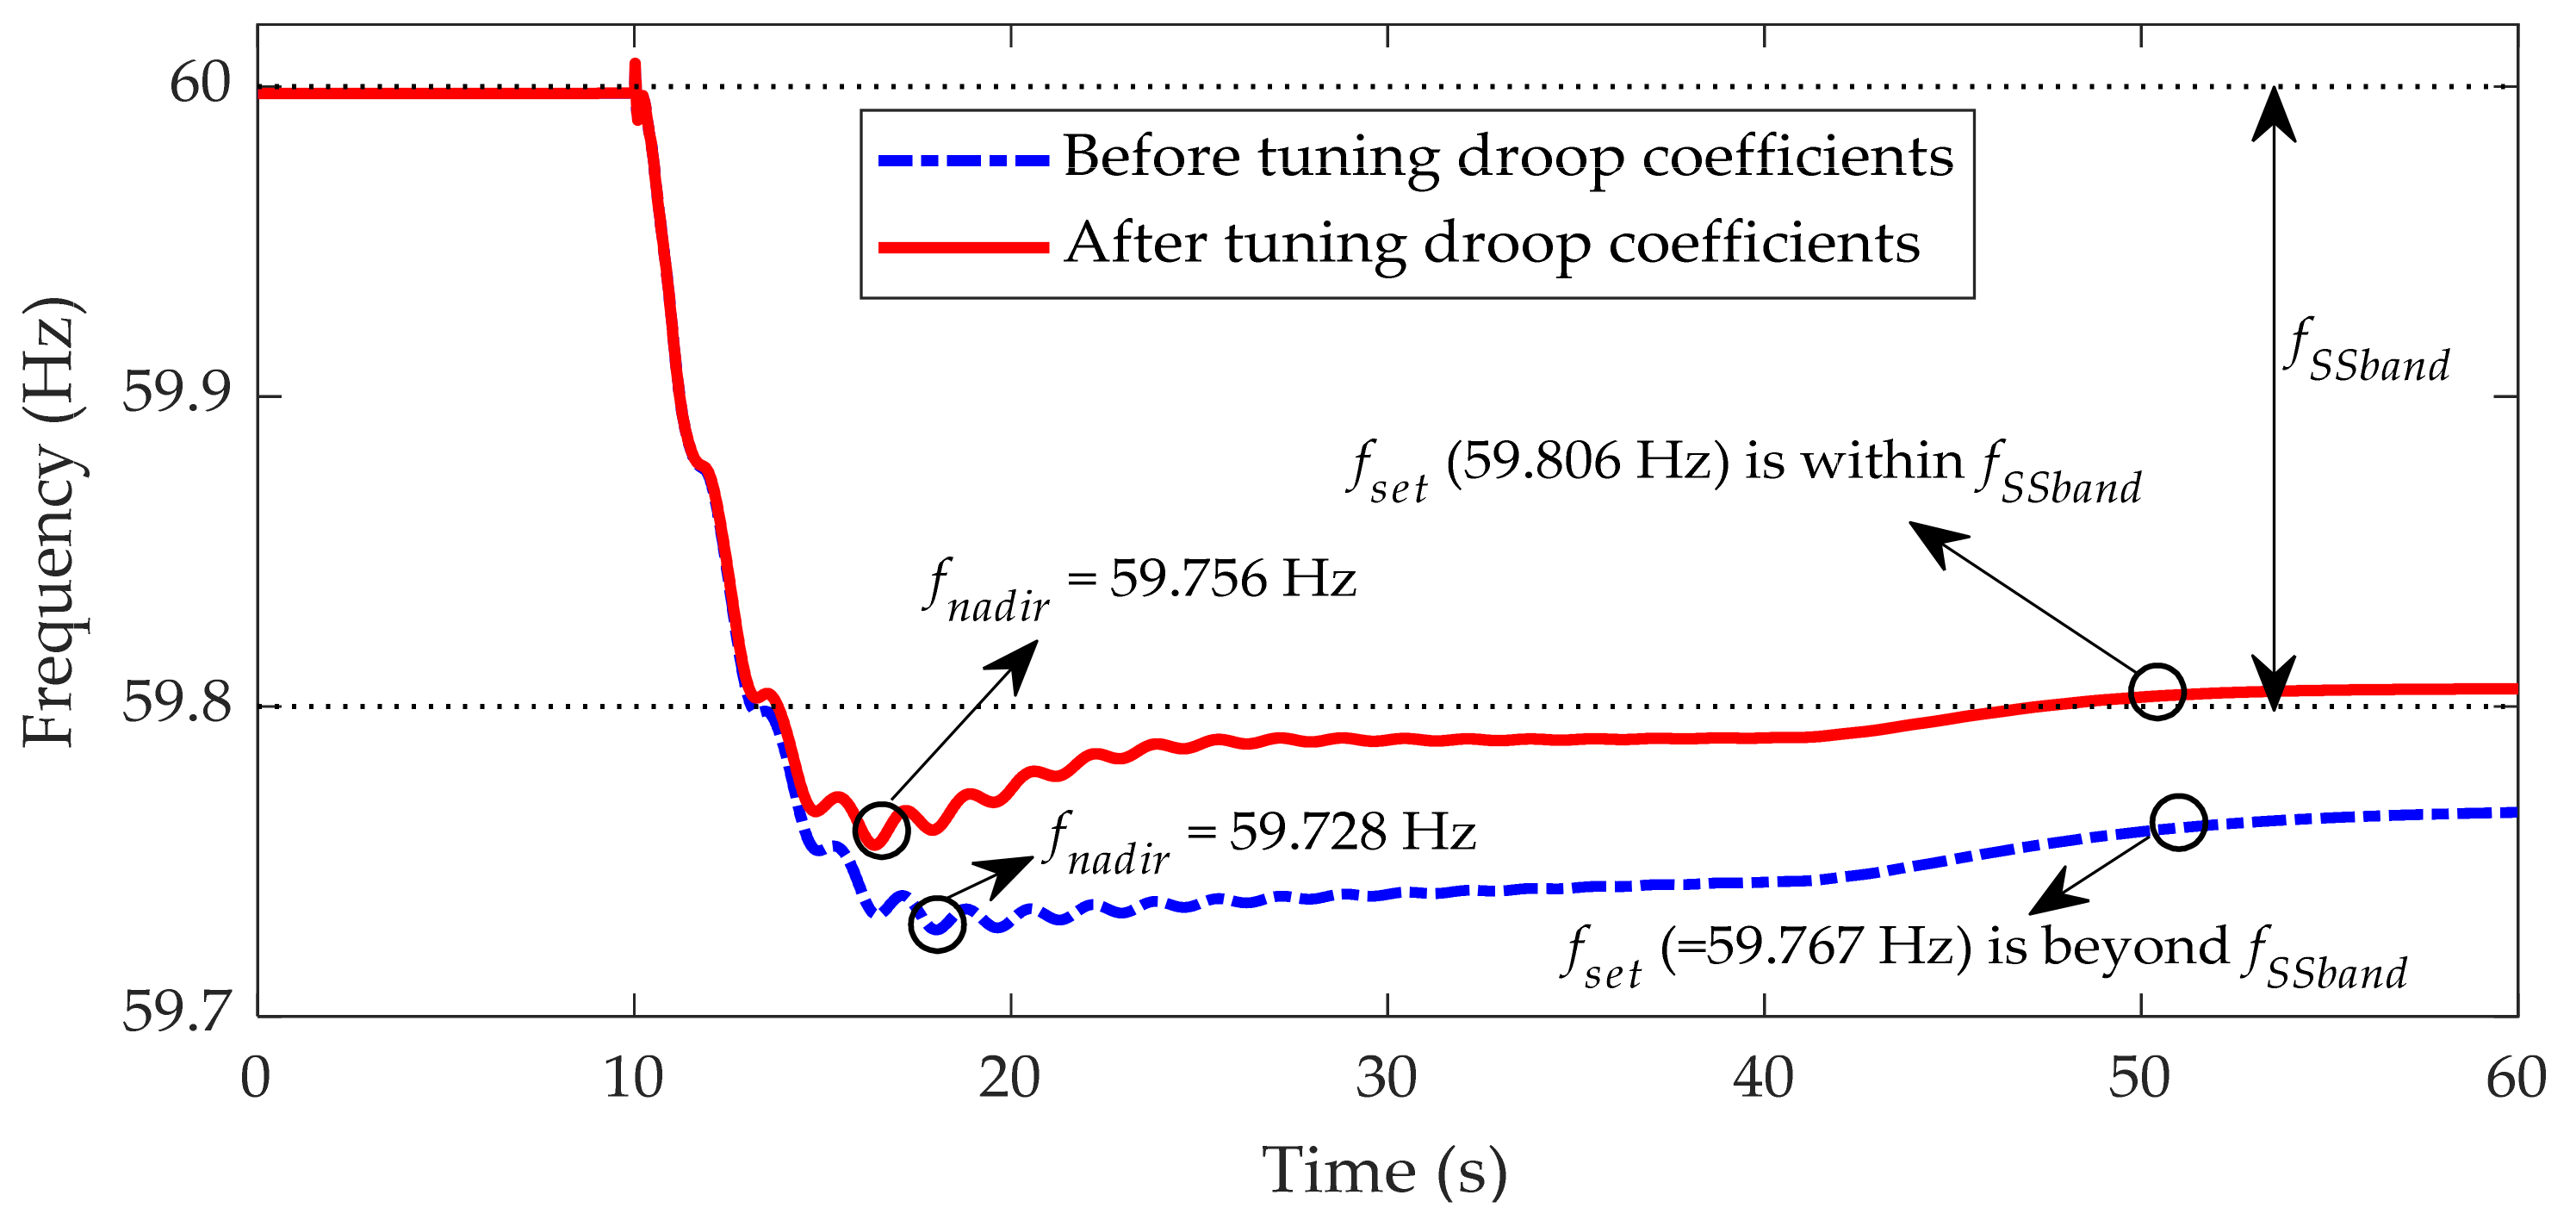
The results of PFR and frequency stability for this case study are shown in Figure 11 and Figure 12. It is observed that the overall PFR provided from SGs is increased compared to case study 1. This is because while WPPs provided PFR in the previous case study, WPPs are assumed that they cannot provide PFR due to technical and operational limits for this case study. Therefore, SGs must provide more PFR to compensate for the loss. As WPPs are not providing any fast frequency responses (IR and PFR) for this case, it is observed that before tuning the droop coefficients, fnadir and fset are decreased by 0.123 Hz and 0.062 Hz, respectively, compared to those of case study 1. However, after tuning the SGs governor droop coefficients by the proposed method, it is observed that both fnadir and fset have been increased by 0.086 Hz and 0.101 Hz, respectively. Moreover, the proposed method has also successfully stabilized the system frequency within the required boundary for this case study. Table 3 summarizes the numerical values of frequency stability indices for all cases.
Figure 11.
Total output power from SGs for case study 2. (a) Region 1, (b) Region 2, (c) Region 3, (d) Region 4, (e) Region 5, and (f) Region 6.
Figure 12.
Results of system frequency for case study 2.
Table 3.
Summary of results for all case studies.
5. Conclusions and Future Work
This paper proposed the method to determine the operation of generation units (GUs) to provide proper primary frequency response (PFR) and recover the severely impacted frequency stability caused by the high penetration of wind power. To do so, the proposed method redetermined the droop coefficient of synchronous generators (SGs) governor while considering the available PFR from wind power plants (WPPs). The validation of the proposed method was verified in the Korean electric power system, including the planned WPPs based on the national energy plan. After analyzing the frequency stability problem caused by this high penetration of WPPs, the proposed method was applied to solve this problem. The simulation results showed that the proposed method successfully recovered the settling frequency within the frequency deviation limit band by the redetermined droop coefficients of SGs governor, which provided proper PFR. In practice, this study is expected to provide useful information in decision-making guidance for a system operator to maintain the frequency stability when the penetration of wind power is increasing.
Moreover, inertial response and PFR were considered in this paper while recovering the frequency stability. However, many control methods are being developed for the newly installed WPPs with the energy storage systems (ESSs) to participate more in the frequency response. Therefore, in the future, the system operator must determine the operation of GUs to maintain the settling and dynamic frequency stability considering PFR and other various responses provided from WPPs and ESSs.
Author Contributions
The research was conducted with the collaboration of all authors. S.L., T.K. and K.Y. wrote the paper; S.L. performed the simulations; D.C. and J.-W.P. supervised the paper. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the National Research Foundation of Korea (NRF) grant funded by the Ministry of Science and ICT (MSIT), Korea government (No. 2020R1A3B2079407).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Not applicable.
Conflicts of Interest
The authors declare no conflict of interest.
Nomenclature
| fnadir | Frequency nadir (Hz) |
| fset | Settling frequency (Hz) |
| β | Composite system frequency response characteristic (MW/0.1 Hz) |
| Pm | Mechanical power (pu) |
| Vw | Wind speed (m/s) |
| ρ | Air density (kg/m3) |
| r | Rotor radius (m) |
| cP | Power coefficient |
| λ | Tip speed ratio (pu) |
| θ | Pitch angle (◦) |
| PMPPT | Maximum output power (pu) |
| cP,max | Optimal power coefficient |
| λopt | Optimal tip speed ratio (pu) |
| ωr | Rotor speed (pu) |
| kopt | Coefficient of the MPPT curve |
| ΔPIC | Power increment by inertial control method (pu) |
| H | Inertia constant (s) |
| ω0 | Initial rotor speed (pu) |
| ωmin | Minimum speed limit (pu) |
| PT-lim | Power refers to the torque limit (pu) |
| ΔPPFR | Power increment by power reserve control method (pu) |
| R | Droop coefficient |
| S | Power capacity (W) |
| fnorm | Nominal value of frequency (Hz) |
| Ploss | Size of generation loss (W) |
| flimit | frequency deviation limit (Hz) |
| βsys_bef | Composite system frequency response characteristic before tuning the droop coefficients (MW/0.1 Hz) |
| fSSband | Frequency deviation limit band (Hz) |
| βreq | Required composite system frequency response characteristic (MW/0.1 Hz) |
| βsys_aft | Composite system frequency response characteristic after tuning the droop coefficients (MW/0.1 Hz) |
| Acronym | |
| WPPs | Wind power plants |
| AGC | Automatic generation control |
| GUs | Generation units |
| SGs | Synchronous generators |
| DGs | Distributed generators |
| MPPT | Maximum power point tracking |
| IR | Inertial response |
| PFR | Primary frequency response |
| ESSs | Energy storage systems |
References
- Kim, J.-H.; Kim, S.-Y.; Yoo, S.-H. Public Acceptance of the “Renewable Energy 3020 Plan”: Evidence from a contingent valuation study in South Korea. Sustainability 2020, 12, 3151. [Google Scholar] [CrossRef] [Scilit]
- Kim, C. A review of the deployment programs, impact, and barriers of renewable energy policies in Korea. Renew. Sustain. Energy Rev. 2021, 144, 110870. [Google Scholar] [CrossRef] [Scilit]
- Ali, E.S.; El-Sehiemy, R.A.; Abou El-Ela, A.A.; Mahmoud, K.; Lehtonen, M.; Darwish, M.M.F. An effective Bi-stage method for renewable energy sources integration into unbalanced distribution systems considering uncertainty. Processes 2021, 9, 471. [Google Scholar] [CrossRef] [Scilit]
- Eto, J.H. Use of Frequency Response Metrics to Assess the Planning and Operating Requirements for Reliable Integration of Variable Renewable Generation; Tech. Rep.; Ernest Orlando Lawrence Berkeley National Laboratory: Berkeley, CA, USA, 2010. [Google Scholar]
- Kosmecki, M.; Rink, R.; Wakszyńska, A.; Ciavarella, R.; Di Somma, M.; Papadimitriou, C.N.; Efthymiou, V.; Graditi, G. A methodology for provision of frequency stability in operation planning of low inertia power systems. Energies 2021, 14, 737. [Google Scholar] [CrossRef] [Scilit]
- Skinder, K.S.; Kerdphol, T.; Mitani, Y.; Turschner, D. Frequency stability assessment of multiple virtual synchronous generators for interconnected power system. IEEE Trans. Ind. Appl. 2022, 58, 91–101. [Google Scholar] [CrossRef] [Scilit]
- Lim, S.; Kim, T.; Yoon, K.; Choi, D.; Park, J.-W. Assessment of frequency response in practical Korea electric power system considering wind power curtailment and inertial response. In Proceedings of the APAP 2021 Conference, Jeju, Korea, 11–14 October 2021. [Google Scholar]
- Jeong, H.G.; Seung, R.H.; Lee, K.B. An improved maximum power point tracking method for wind power systems. Energies 2012, 5, 1339–1354. [Google Scholar] [CrossRef] [Scilit]
- Shrestha, A.; Gonzalez-Longatt, F. Frequency stability issues and research opportunities in converter dominated power system. Energies 2021, 14, 4184. [Google Scholar] [CrossRef] [Scilit]
- Patsalides, M.; Papadimitriou, C.N.; Efthymiou, V.; Ciavarella, R.; Di Somma, M.; Wakszyńska, A.; Kosmecki, M.; Graditi, G.; Valenti, M. Frequency stability evaluation in low inertia systems utilizing smart hierarchical controllers. Energies 2020, 13, 3506. [Google Scholar] [CrossRef] [Scilit]
- Edrisian, A.; Goudarzi, A.; Ebadian, M. Investigating the effect of high level of wind penetration on voltage stability by quasi-static time domain simulation (QSTDS). Int. J. Renew. Energy Res. (IJRER) 2014, 4, 355–362. [Google Scholar] [CrossRef]
- Edrisian, A.; Goudarzi, A.; Davidson, I.E.; Ahmadi, A.; Venayagamoorthy, G.K. Enhancing SCIG-based wind turbine generator performance through reactive power control. In Proceedings of the Clemson University Power Systems Conference (PSC), Clemson, SC, USA, 10–13 March 2015. [Google Scholar]
- Elsisi, M.; Tran, M.-Q.; Mahmoud, K.; Lehtonen, M.; Darwish, M.M.F. Robust design of ANFIS-based blade pitch controller for wind energy conversion systems against wind speed fluctuations. IEEE Access 2021, 9, 37894–37904. [Google Scholar] [CrossRef] [Scilit]
- Ali, M.N.; Soliman, M.; Mahmoud, K.; Guerrero, J.M.; Lehtonen, M.; Darwish, M.M.F. Resilient design of robust multi-objectives PID controllers for automatic voltage regulators: D-decomposition approach. IEEE Access 2021, 9, 106589–106605. [Google Scholar] [CrossRef] [Scilit]
- Shang, L.; Hu, J.; Yuan, X.; Chi, Y. Understanding inertial response of variable-speed wind turbines by defined internal potential vector. Energies 2016, 10, 22. [Google Scholar] [CrossRef] [Scilit]
- Mujcinagic, A.; Kusljugic, M.; Nukic, E. Wind inertial response based on the center of inertia frequency of a control area. Energies 2020, 13, 6177. [Google Scholar] [CrossRef] [Scilit]
- Kang, M.; Kim, K.; Muljadi, E.; Park, J.; Kang, Y.C. Frequency control support of a doubly-fed induction generator based on the torque limit. IEEE Trans. Power Syst. 2016, 31, 4575–4583. [Google Scholar] [CrossRef] [Scilit]
- Yang, D.; Kim, J.; Kang, Y.C.; Muljadi, E.; Zhang, N.; Hong, J.; Song, S.; Zheng, T. Temporary frequency support of a DFIG for high wind power penetration. IEEE Trans. Power Syst. 2018, 33, 3428–3437. [Google Scholar] [CrossRef] [Scilit]
- Siniscalchi-Minna, S.; Bianchi, F.D.; De-Prada-Gil, M.; Ocampo-Martinez, C. A wind farm control strategy for power reserve maximization. Renew. Energy 2019, 131, 37–44. [Google Scholar] [CrossRef] [Scilit]
- Li, J.; Ma, Y.; Mu, G.; Feng, X.; Yan, G.; Guo, G.; Zhang, T. Optimal configuration of energy storage system coordinating wind turbine to participate power system primary frequency regulation. Energies 2018, 11, 1396. [Google Scholar] [CrossRef] [Scilit]
- Wang, S.; Tomsovic, K. A novel active power control framework for wind turbine generators to improve frequency response. IEEE Trans. Power Syst. 2018, 33, 6579–6589. [Google Scholar] [CrossRef] [Scilit]
- Luo, H.; Hu, Z.; Zhang, H.; Chen, H. Coordinated active power control strategy for deloaded wind turbines to improve regulation performance in AGC. IEEE Trans. Power Syst. 2019, 34, 98–108. [Google Scholar] [CrossRef] [Scilit]
- Choi, W.Y.; Kook, K.S. Impact analysis of BESS for providing frequency response in Korean power system. In Proceedings of the APAP 2017 Conference, Jeju, Korea, 16–19 October 2017. [Google Scholar]
- Choi, W.Y.; Kook, K.S.; Yu, G.R. Control strategy of BESS for providing both virtual inertia and primary frequency response in the Korean power system. Energies 2019, 12, 4060. [Google Scholar] [CrossRef] [Scilit]
- Guan, M. Scheduled power control and autonomous energy control of grid-connected energy storage system (ESS) with virtual synchronous generator and primary frequency regulation capabilities. IEEE Trans. Power Syst. 2021. [Google Scholar] [CrossRef] [Scilit]
- Henke, M.; Hailu, G. Thermal management of stationary battery systems: A literature review. Energies 2020, 13, 4194. [Google Scholar] [CrossRef] [Scilit]
- Lee, H.-J.; Kim, K.-T.; Park, J.-H.; Bere, G.; Ochoa, J.J.; Kim, T. Convolutional neural network-based false battery data detection and classification for battery energy storage systems. IEEE Trans. Energy Convers. 2021, 36, 3108–3117. [Google Scholar] [CrossRef] [Scilit]
- Alsharafi, A.S.; Besheer, A.H.; Emara, H.M. Primary frequency response enhancement for future low inertia power systems using hybrid control technique. Energies 2018, 11, 699. [Google Scholar] [CrossRef] [Scilit]
- Kim, J.-K.; Lee, S.H.; Kim, J.-S.; Choi, H. The need for modeling the impact of behind-the-meter generation trip on primary frequency response through operational experiences in Korea power system. IEEE Trans. Power Syst. 2022. [Google Scholar] [CrossRef] [Scilit]
- Chvez, H.; Hezamsadeh, M.R.; Carlsson, F. A simplified model for predicting primary control inadequacy for nonresponsive wind power. IEEE Trans. Sustain. Energy 2016, 7, 271–278. [Google Scholar] [CrossRef] [Scilit]
- Lee, J.; Muljadi, E.; Srensen, P.; Kang, Y.C. Releasable kinetic energy-based inertial control of a DFIG wind power plant. IEEE Trans. Sustain. Energy 2016, 7, 279–288. [Google Scholar] [CrossRef] [Scilit]
- Lee, Y.; Lee, H.; Gim, J.; Seo, I.; Lee, G. Technical measures to mitigate load fluctuation for large-scale customers to improve power system energy efficiency. Energies 2020, 13, 4812. [Google Scholar] [CrossRef] [Scilit]
- Ribó-Pérez, D.; Larrosa-López, L.; Pecondón-Tricas, D.; Alcázar-Ortega, M. A critical review of demand response products as resource for ancillary services: International experience and policy recommendations. Energies 2021, 14, 846. [Google Scholar] [CrossRef] [Scilit]
- Vidyanandan, K.V.; Senroy, N. Primary frequency regulation by deloaded wind turbines using variable droop. IEEE Trans. Power Syst. 2013, 28, 837–846. [Google Scholar] [CrossRef] [Scilit]
- Acosta, M.N.; Pettersen, D.; Gonzalez-Longatt, F.; Peredo Argos, J.; Andrade, M.A. Optimal frequency support of variable-speed hydropower plants at Telemark and Vestfold, Norway: Future scenarios of Nordic power system. Energies 2020, 13, 3377. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).