


Abstract
The most efficient energy management strategies for hybrid vehicles are the “Optimization-Based Strategies”. These strategies require a preliminary knowledge of the driving cycle, which is not easy to predict. This paper aims to combine Worldwide Harmonized Light-Duty Vehicles Test Cycle (WLTC) low section short trips with real traffic levels for vehicle energy and fuel consumption prediction. Future research can focus on implementing a new strategy for Hybrid Electric Vehicle (HEV) energy optimization, taking into account WLTC and Google Maps traffic levels. First of all, eight characteristic parameters are extracted from real speed profiles, driven in urban road sections in the city of Messina at different traffic conditions, and WLTC short trips as well. The minimum distance algorithm is used to compare the parameters and assign the three traffic levels (heavy, average, and low traffic level) to the WLTC short trips. In this way, for each route assigned from Google maps, vehicle’s energy and fuel consumption are estimated using WLTC short trips remodulated with distances and traffic levels. Moreover, a vehicle numerical model was implemented and used to test the accuracy of fuel consumption and energy prediction for the proposed methodology. The results are promising since the average of the percentage errors’ absolute value between the experimental driving cycles and forecast ones is 3.89% for fuel consumption, increasing to 6.80% for energy.
1. Introduction
One of the most Hybrid Electric Vehicle (HEV) advantages is the possibility to optimize the use of energy storage during the trip using the Energy Management System (EMS). Zhou et al. [1] categorize EMSs in:
- Rule-Based Strategies (RBSs): These strategies define a local optimization of the powertrain’s operating points. They use only the battery State of Charge (SOC) knowledge and the driver’s load signal [2] to manage the vehicle’s power. RBSs are easy to implement and require low computational cost, but energy management efficiency is modest. One example of RBS is presented by Bagwe et al. [3] and Wu et al. [4].
- Optimization-Based Strategies (OBSs): These strategies define a global optimization of the powertrain’s operating points. They optimize energy management by considering the car’s whole Driving Cycle (DC), so the optimization depends on both internal and external parameters of the vehicle. The OBS’s energy management efficiency is higher than RBS; on the other hand, they require a high computational cost, a significant complexity, and the prediction of DC. One example of OBS is presented by Fang et al. [5] and Wu et al. [6].
The scientific community is proposing numerous techniques for predicting the driving cycle. Wang et al. [7] summarize the prediction techniques in three categories:
- Statistic and Cluster Analysis based Recognition: this category collects the techniques that use the historical and current vehicle’s speed profile parameters to predict future conditions. The techniques differ for the number of the analyzed parameters (for example, sixty-two presented by Ericson et al. [8], eleven by Xi et al. [9], and three by Chen et al. [10]), for the length of the prediction time window, and for parameter’s analysis methods (Bayesian classifying algorithm, decision tree, fuzzy clustering analysis, neural network). Neural Network (NN) is the most common method according to Wang et al. [7], and it is used by Langari et al. [11], by Jeon et al. [12] and by Han et al. [13].
- Markov Chain-Based Predictive Control: this category collects the techniques that use the current vehicle’s state to predict future conditions. All the techniques are based on the stochastic Markov chain prediction process but differ for the optimization algorithm. Some examples of optimization algorithms are the Pontryagin Minimum Principle (used by Liu et al. [14]), the Stochastic Dynamic Programming (used by Johannesson et al. [15] and by Lin et al [16]), Genetic Fuzzy Logic control (used by Chaofeng et al. [17]), and NN (used by Shen et al. [18]).
- Global Positioning System (GPS) and Intelligent Transportation Systems (ITS) based prediction: this category collects the techniques that use the historical and current vehicle’s parameter, GPS, and ITS data to forecast the DC.
Numerous researches belong to the third category. Zhang et al. [19] use prior knowledge of the car’s route altimetry profile (provided by GPS) to optimize the power split between energy sources in an HEV. Qiuming et al. [20] use ITS data to assign a speed profile to a specific road section. The speed profile depends on the traffic light distribution, the average speed of the vehicle’s flow-rate, and the historical traffic state data. He et al. [21] use a dataset similar to Qiuming et al. [20] assigning a driving cycle in a freeway road section. The main difference is the possibility to modify the speed profile according to the car’s GPS information. Zhang et al. [22] use data similar to He et al. [21], adding the near field vehicles’ GPS information. A NN makes up the DC and uses it to predict each vehicle’s energy expenditure for a ten-second length time window.
The third category also includes some articles that consider the Worldwide Harmonized Light-Duty Vehicles Test Cycle (WLTC). Hu et al. [23] develop an EMS optimization based on speed profile, traffic status, and road gradient knowledge. They assign to the WLTC a road grade profile and a traffic state according to a threshold velocity. It is possible to evaluate the EMS performance assuming that the vehicle under test will be in this condition. Yavasoglu et al. [24] trained a neural network to predict an electric vehicle’s actual residual autonomy. The autonomy estimation is based on GPS (itinerary, road gradient profile) and ITS (traffic) information. If GPS and ITS information are not available, the neural network predicts the remaining range based on 19 training set parameters extracted from the WLTC. The NN compares the training set and the car’s instantaneous parameters value to estimate the remaining autonomy.
Considering all the research, it is clear that the EMSs can forecast the vehicle’s energy expenditure and fuel consumption only if many data are available. It means the use of sensor-equipped cars and cities, which is not always easy to achieve.
This paper investigates the possibility to predict the amount of fuel and energy consumed by a vehicle using a limited number of parameters and sensors to achieve a simple, easily implemented, and cost-effective prediction. The starting point of the research was the assumption that vast majority of the population and new generation vehicle can easily access GPS software (such as Google Maps). Google Maps (Mountain View, CA, USA) can provide information about the route’s altitude, the distance to be driven, and the intensity of traffic. Its algorithm gives easy to read GPS and ITS data. The second assumption was that WLTC collects speed profiles made by worldwide drivers and performed in different traffic conditions, making it universal.
This paper aims to combine WLTC low section short trips with real traffic levels for vehicle energy and fuel consumption prediction.
The first step was to drive road sections in the city of Messina, recording the traffic information and speed profile provided by Google Maps (GM) and Trackaddict (HP Tuners, Buffalo Grove, IL, USA). Only a smartphone was needed to carry out the data collection campaign, which was, therefore, extremely economical. Three databases were created containing the speed profiles collected under the same traffic condition (red in GM for high traffic intensity, yellow in GM for medium traffic intensity, and green in GM for low traffic intensity). Each database was filtered to compare the experimental speed profiles with the WLTC’s short trips. Eight parameters were extracted from profiles of each database and from the individual short trips that make up the WLTC low section. Through the minimum distance calculation, parameters for each database were compared with short trips’ ones. The algorithm assigned the WLTC’s short trips the traffic level that best suits them. By substituting GM’s road sections with the WLTC’s short trips, respecting the traffic levels and distances, the DC used to forecast fuel and energy was obtained. A dynamic numerical model of a passenger car was created, using the potential of the AVL Cruise-M™ software (AVL, Graz, Austria), to evaluate the forecasting accuracy. The model setup and validation were based on literature data.
Simulations were conducted to evaluate the quality of the prediction method. The results highlight that the methodology forecasts fuel consumption and energy expenditure with acceptable errors, considering the small amount of information it requires. The GM algorithm and WLTC have worldwide nature so the study suits all cities without modifying or adding infrastructure.
2. Vehicle Mathematical Model and Validation
A dynamic numerical model was developed in the AVL Cruise-M™ environment to solve the vehicle’s longitudinal motion equation. Douglas et al [25] describe a 1.6 L four-cylinder spark-ignition engine (SI) engine, Front-Wheel Drive, with a five-speed manual gearbox vehicle. This paper refers to Douglas et al. [25] for the model implementation and validation of results. Table 1 summarizes the engine specifications and the vehicle data used in the simulations.
Table 1.
Vehicle and engine specifications.
The model calculates the thrust that the engine must provide to perform the driving cycle and to overcome the resistance’s forces to motion, which are the aerodynamic drag, the rolling resistance, and the gradient loading.
Table 1 contains the data to calculate the inertia and the drag force. For the calculation of the tire rolling resistance coefficient, the method proposed by Cooper [26], expressed in Equation (1), was taken into account.
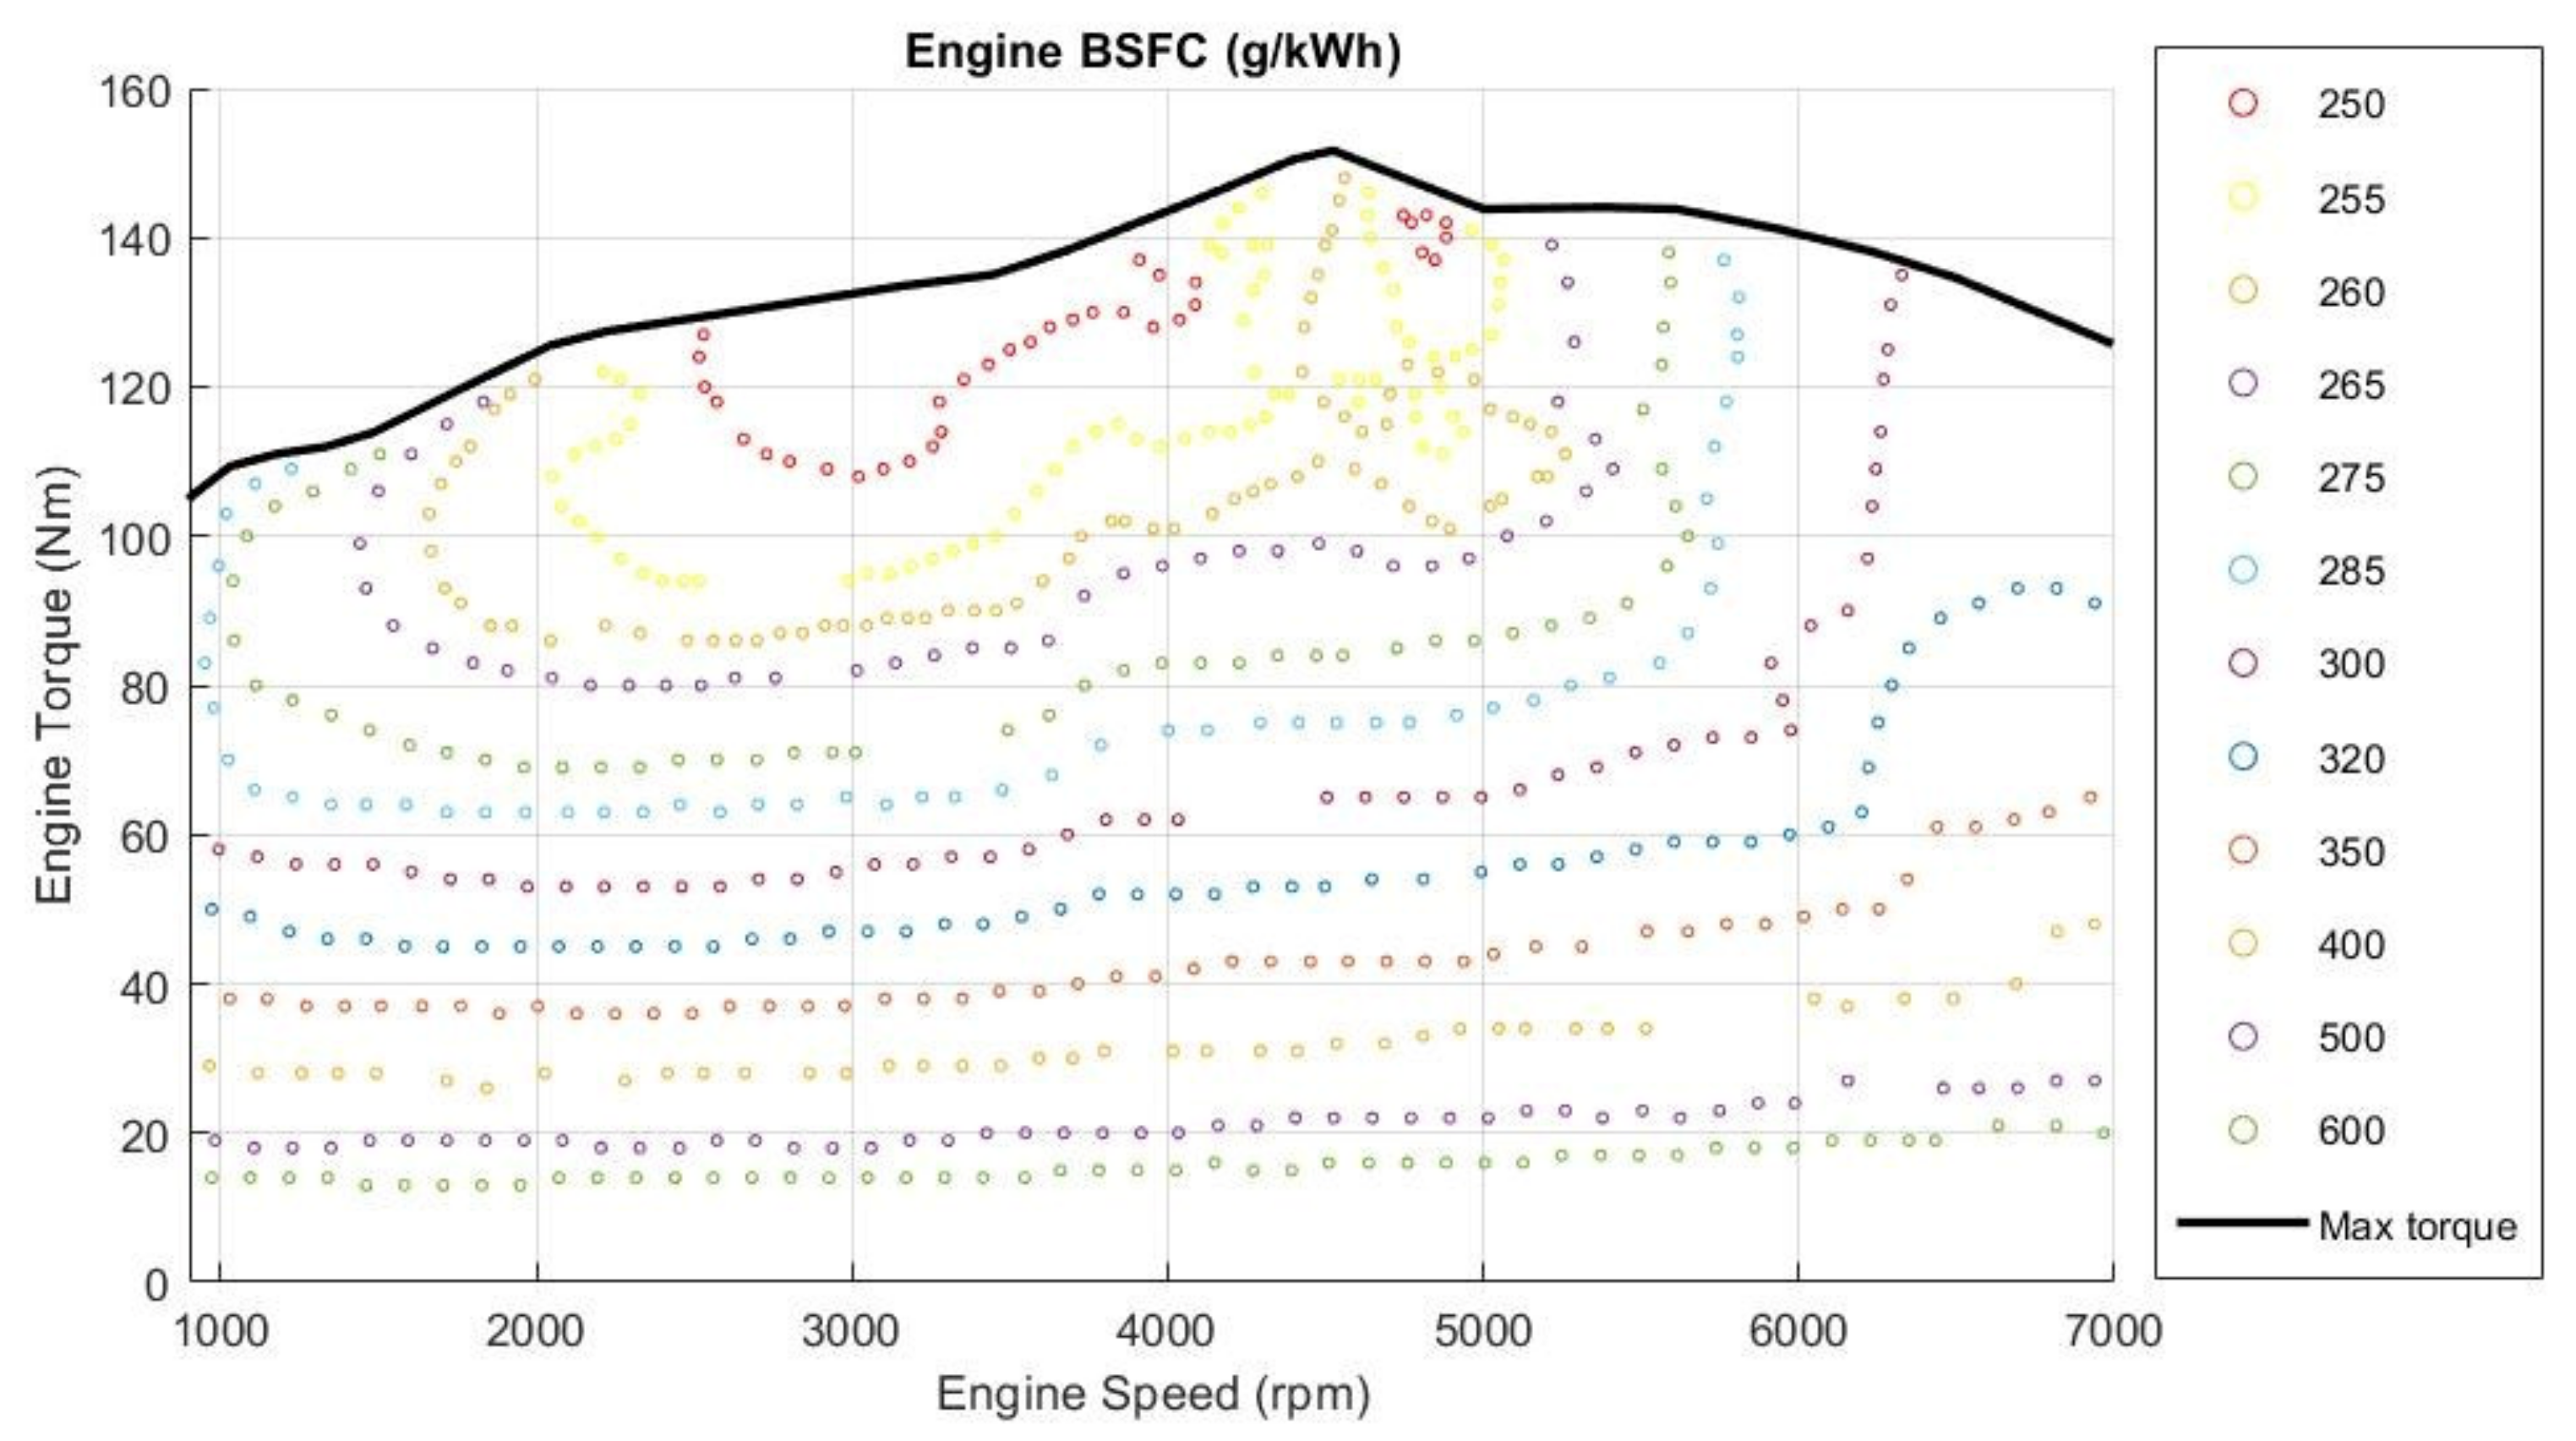
where µ is the rolling resistance coefficient, p is the tire pressure expressed in bar and V is the vehicle velocity expressed in km/h. Douglas et al. [25] report the Engine Brake-specific fuel consumption (BSFC) map and the full load curve used to determine the vehicle’s performance. The driver, modeled as PI control, generates a load signal to request traction proportional to the full load torque curve, in relation to the actual engine speed. BSFC map and the maximum torque curve of the engine are shown in Figure 1. The BSFC map numerical values are extracted by using “WebPlotPigitizer” software (Pacifica, CA, USA) and Table A1 in Appendix A shows them.
µ = 0.0085 + (0.018/p) + (1.59∙10−6/p)∙V2 If V < 165 km/h
µ = (0.018/p) + (2.91∙10−6/p)∙V2 If V > 165 km/h
µ = (0.018/p) + (2.91∙10−6/p)∙V2 If V > 165 km/h
Figure 1.
Engine’s full load torque and Brake-specific fuel consumption (BSFC).
The map presents the full load engine’s torque curve in Nm and the fuel consumption in g/kWh. Consumption was converted into g/s to implement it quickly in the AVL Cruise-M™ workspace, by the Equation (2).
where NEng is the engine’s speed, TEng is the engine’s torque, and BSFC represents the consumption at the operating point considered.
ṁfuel = (BSFC∙NEng∙TEng)/(3.6 × 106)
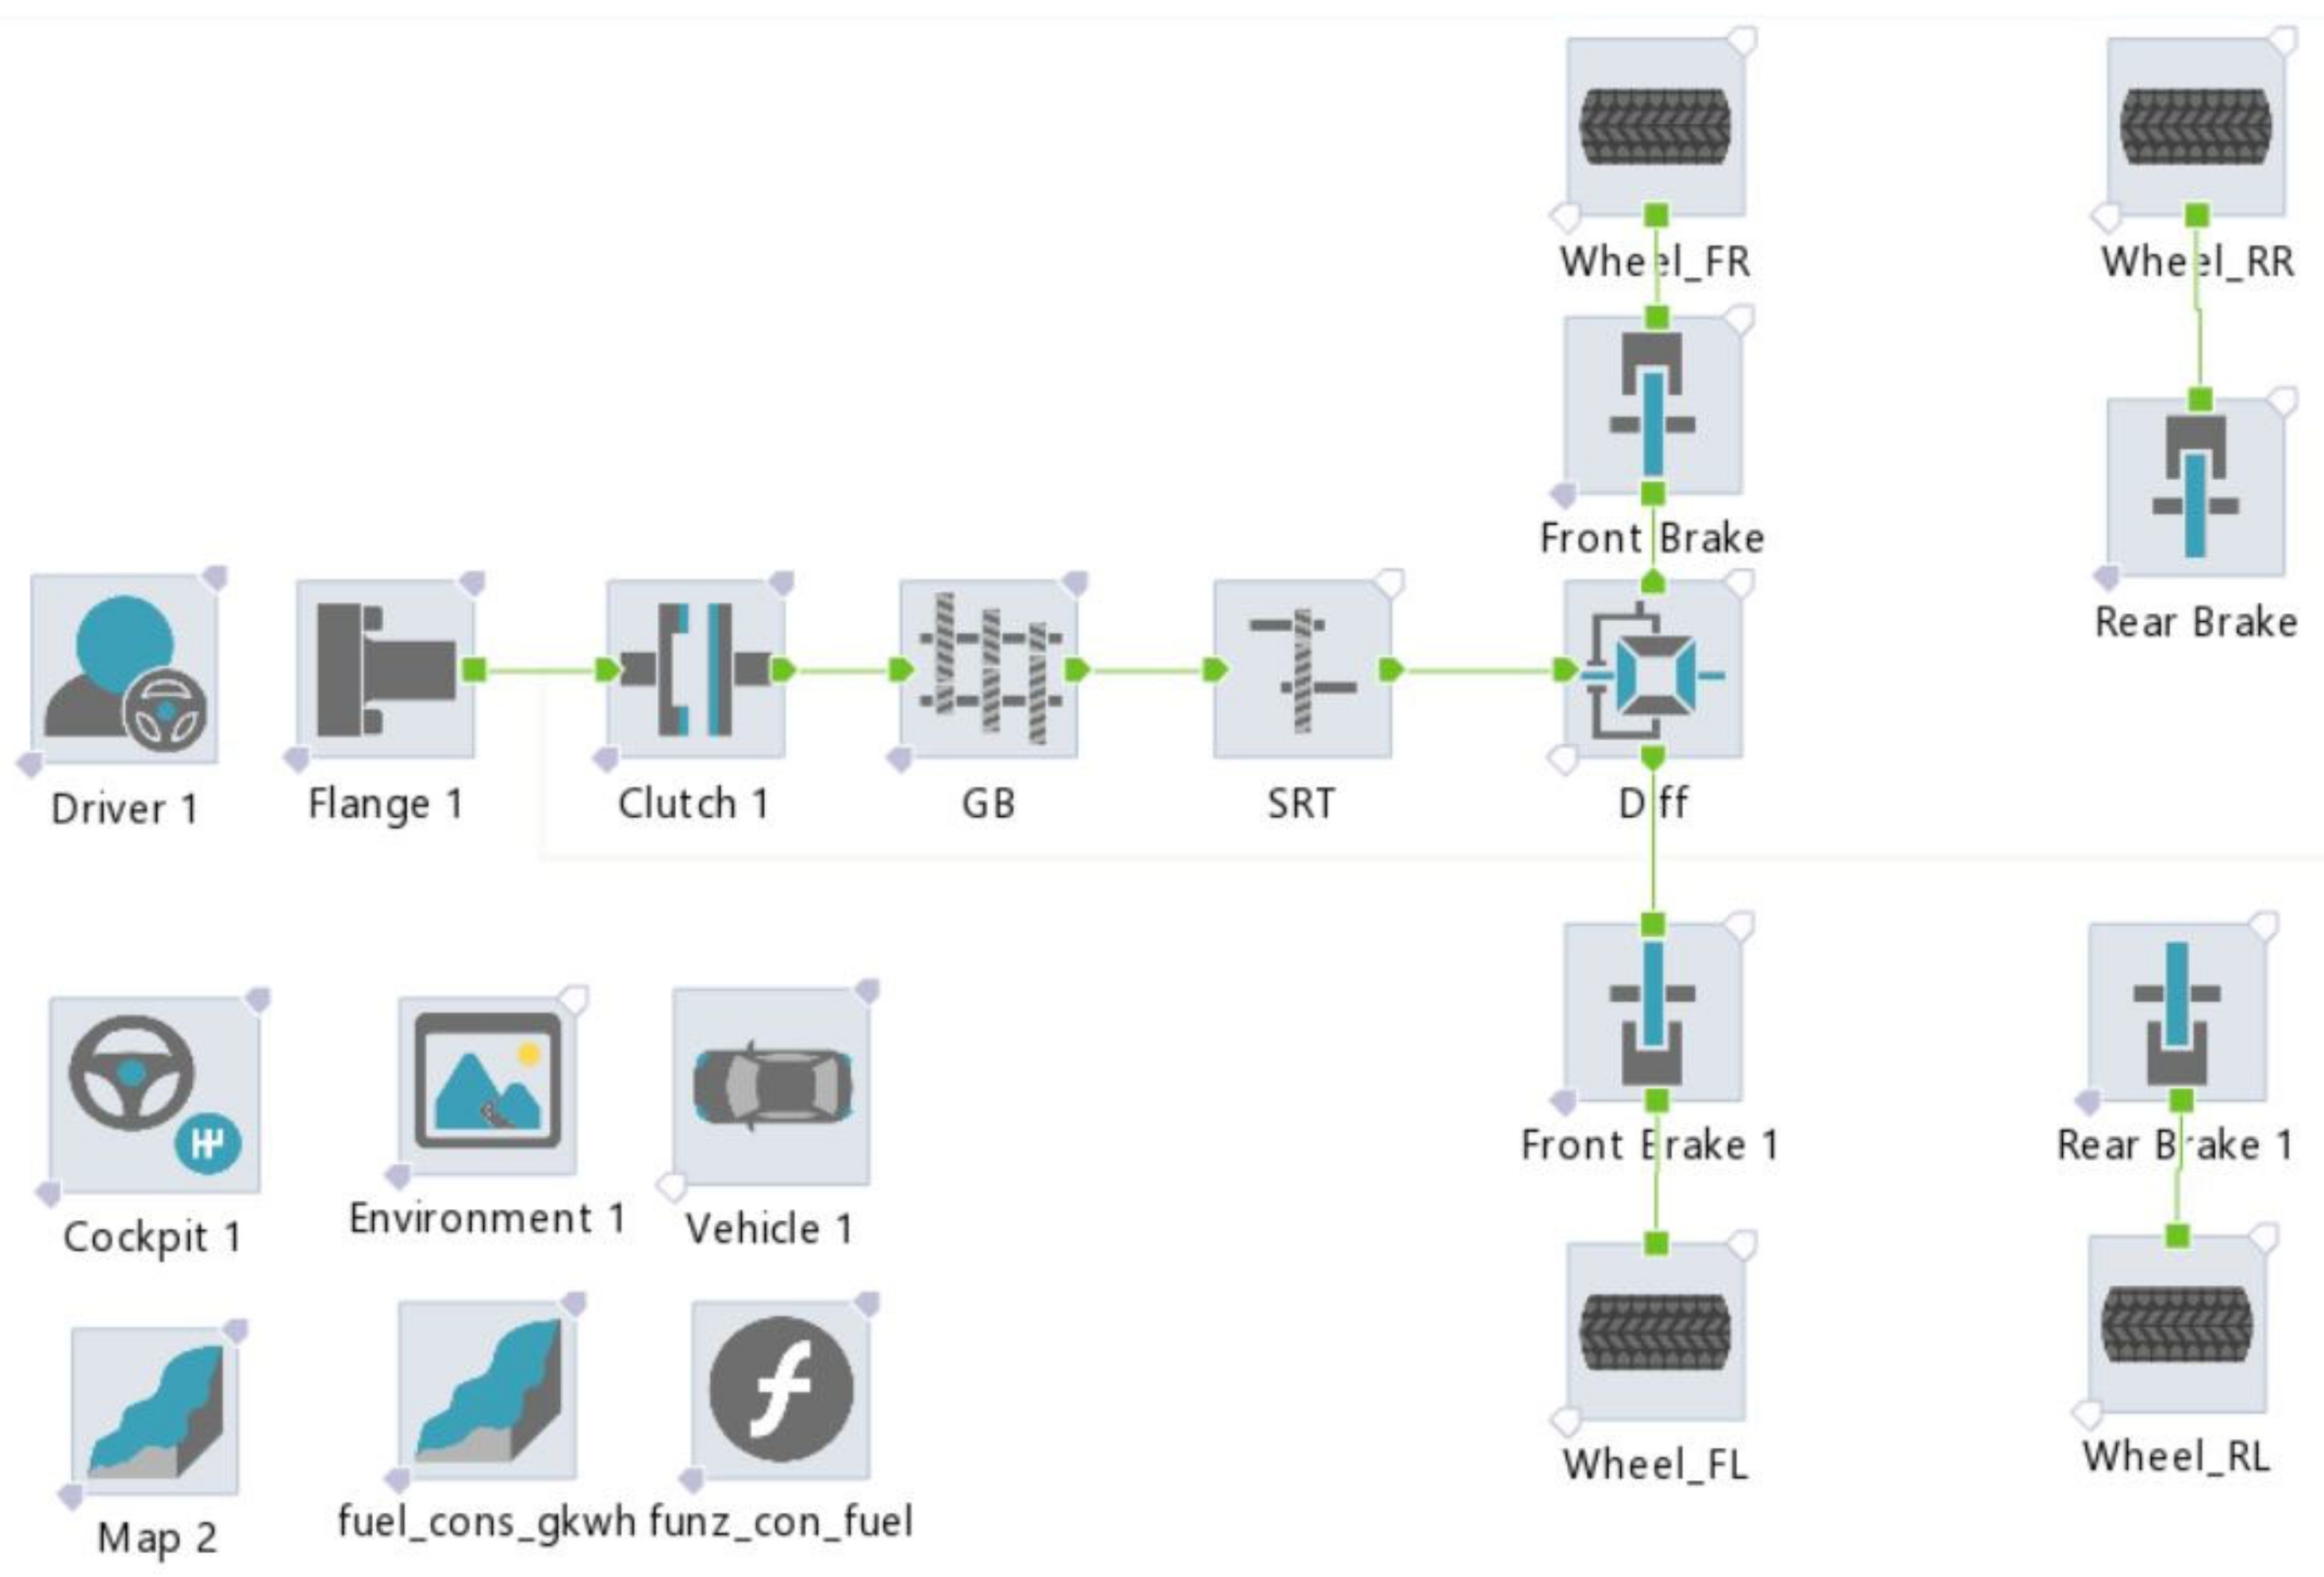
Figure 2 shows all the AVL Cruise-M™ library’s components that build up the model and their links.
Figure 2.
Vehicle’s plan model on the AVL Cruise-M™ workspace.
Douglas et al. [25] present two experimental tests performed by the reference car. The first test measures the vehicle’s maximum acceleration performance in 0–100 km/h speed range. The second test measures the vehicle’s fuel consumption during the New European Driving Cycle (NEDC)test procedure execution. This study refers to these experimental data for numerical model validation.
2.1. Maximum Acceleration
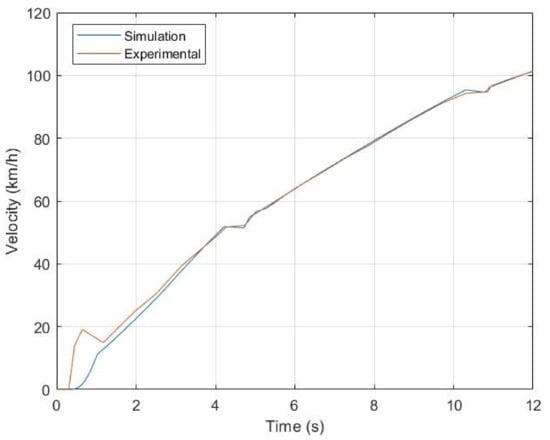
The first simulation highlights the vehicle’s performance in the acceleration from a standing start to 100 km/h. Simulation evaluates the vehicle’s maximum speed too. The shifting strategy was set to perform the gear upshifting at 6700 rpm of engine speed, with a gear change duration of 0.5 s. The launching speed was set to be 1000 rpm as performed in the experimental test. For all simulation time, except during the gear change, the driver’s load signal was equal to 100%. The simulated results are very similar to the experiment presented in Douglas et al. [25]. The shift from 1st to 2nd gear occurring at 4.315 s for the simulated vehicle and 4.10 s for the real one (5.24% of percentage error), the upshift from 2nd to 3rd occurs at 10.395 s, 0.2 s delay compared to the experimental data (2.92% of percentage error). Percentage error decreases at the 100 km/h (2.58%) and at the maximum velocity’s evaluation (−1.01%). Figure 3 shows the correlation achieved between simulated and measured data. Table 2 collects the parameters considered for the validation of the model in this case.
Figure 3.
Maximum acceleration comparison between measured and simulated results.
Table 2.
Results in maximum acceleration test.
From comparison with experimental data, it is possible to assert that the model describes the real vehicle with an acceptable error. Only between 0 s and 1.8 s the simulated results do not closely mimic that found in the experimental test, due probably to a different clutch release. The lack of data on clutch management makes it impossible to compare the model and the real car in the starting phases. Inertias, efficiencies, and resistance forces of the numerical model can adequately describe the real vehicle.
2.2. NEDC Test Procedure
Following the workflow presented by Douglas et al. [25], the NEDC test procedure was simulated to validate the vehicle’s fuel consumption and PI control setting. The procedure defines the gear-shifting strategy. The NEDC requires a cold start to describe the vehicle’s performance adequately. Still, the Engine BSFC map was available only for steady-state operating temperature, so differences were expected from experimental tests in the “cold” region of the NEDC. To overcome this problem, Douglas et al. [25] suggest applying the corrections described in Equation (3).
ṁfuel cold = 4∙ṁfuel hot If 0 s < t < 80 s
ṁfuel cold = 1.4∙ṁfuel hot If 80 s < t < 230 s
ṁfuel cold = 1.4∙ṁfuel hot If 80 s < t < 230 s
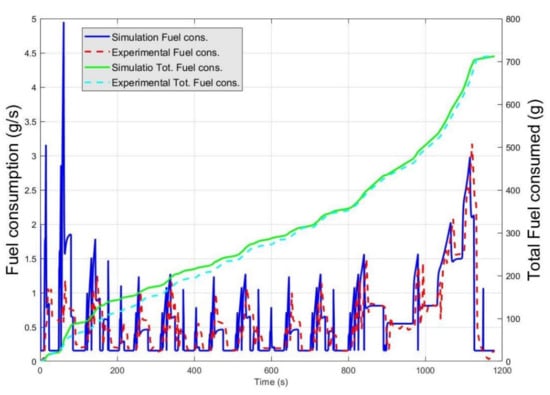
At 230 s, the engine coolant temperature is almost 85 °C, which is the engine’s average running temperature. Moreover, the fuel consumption lower limit was set to 0.156 g/s to emulate the car’s idle consumption. Figure 4 shows the correlation between measured and simulated fuel consumption, both instantaneous and in the accumulative form.
Figure 4.
Fuel consumption in New European Driving Cycle (NEDC).
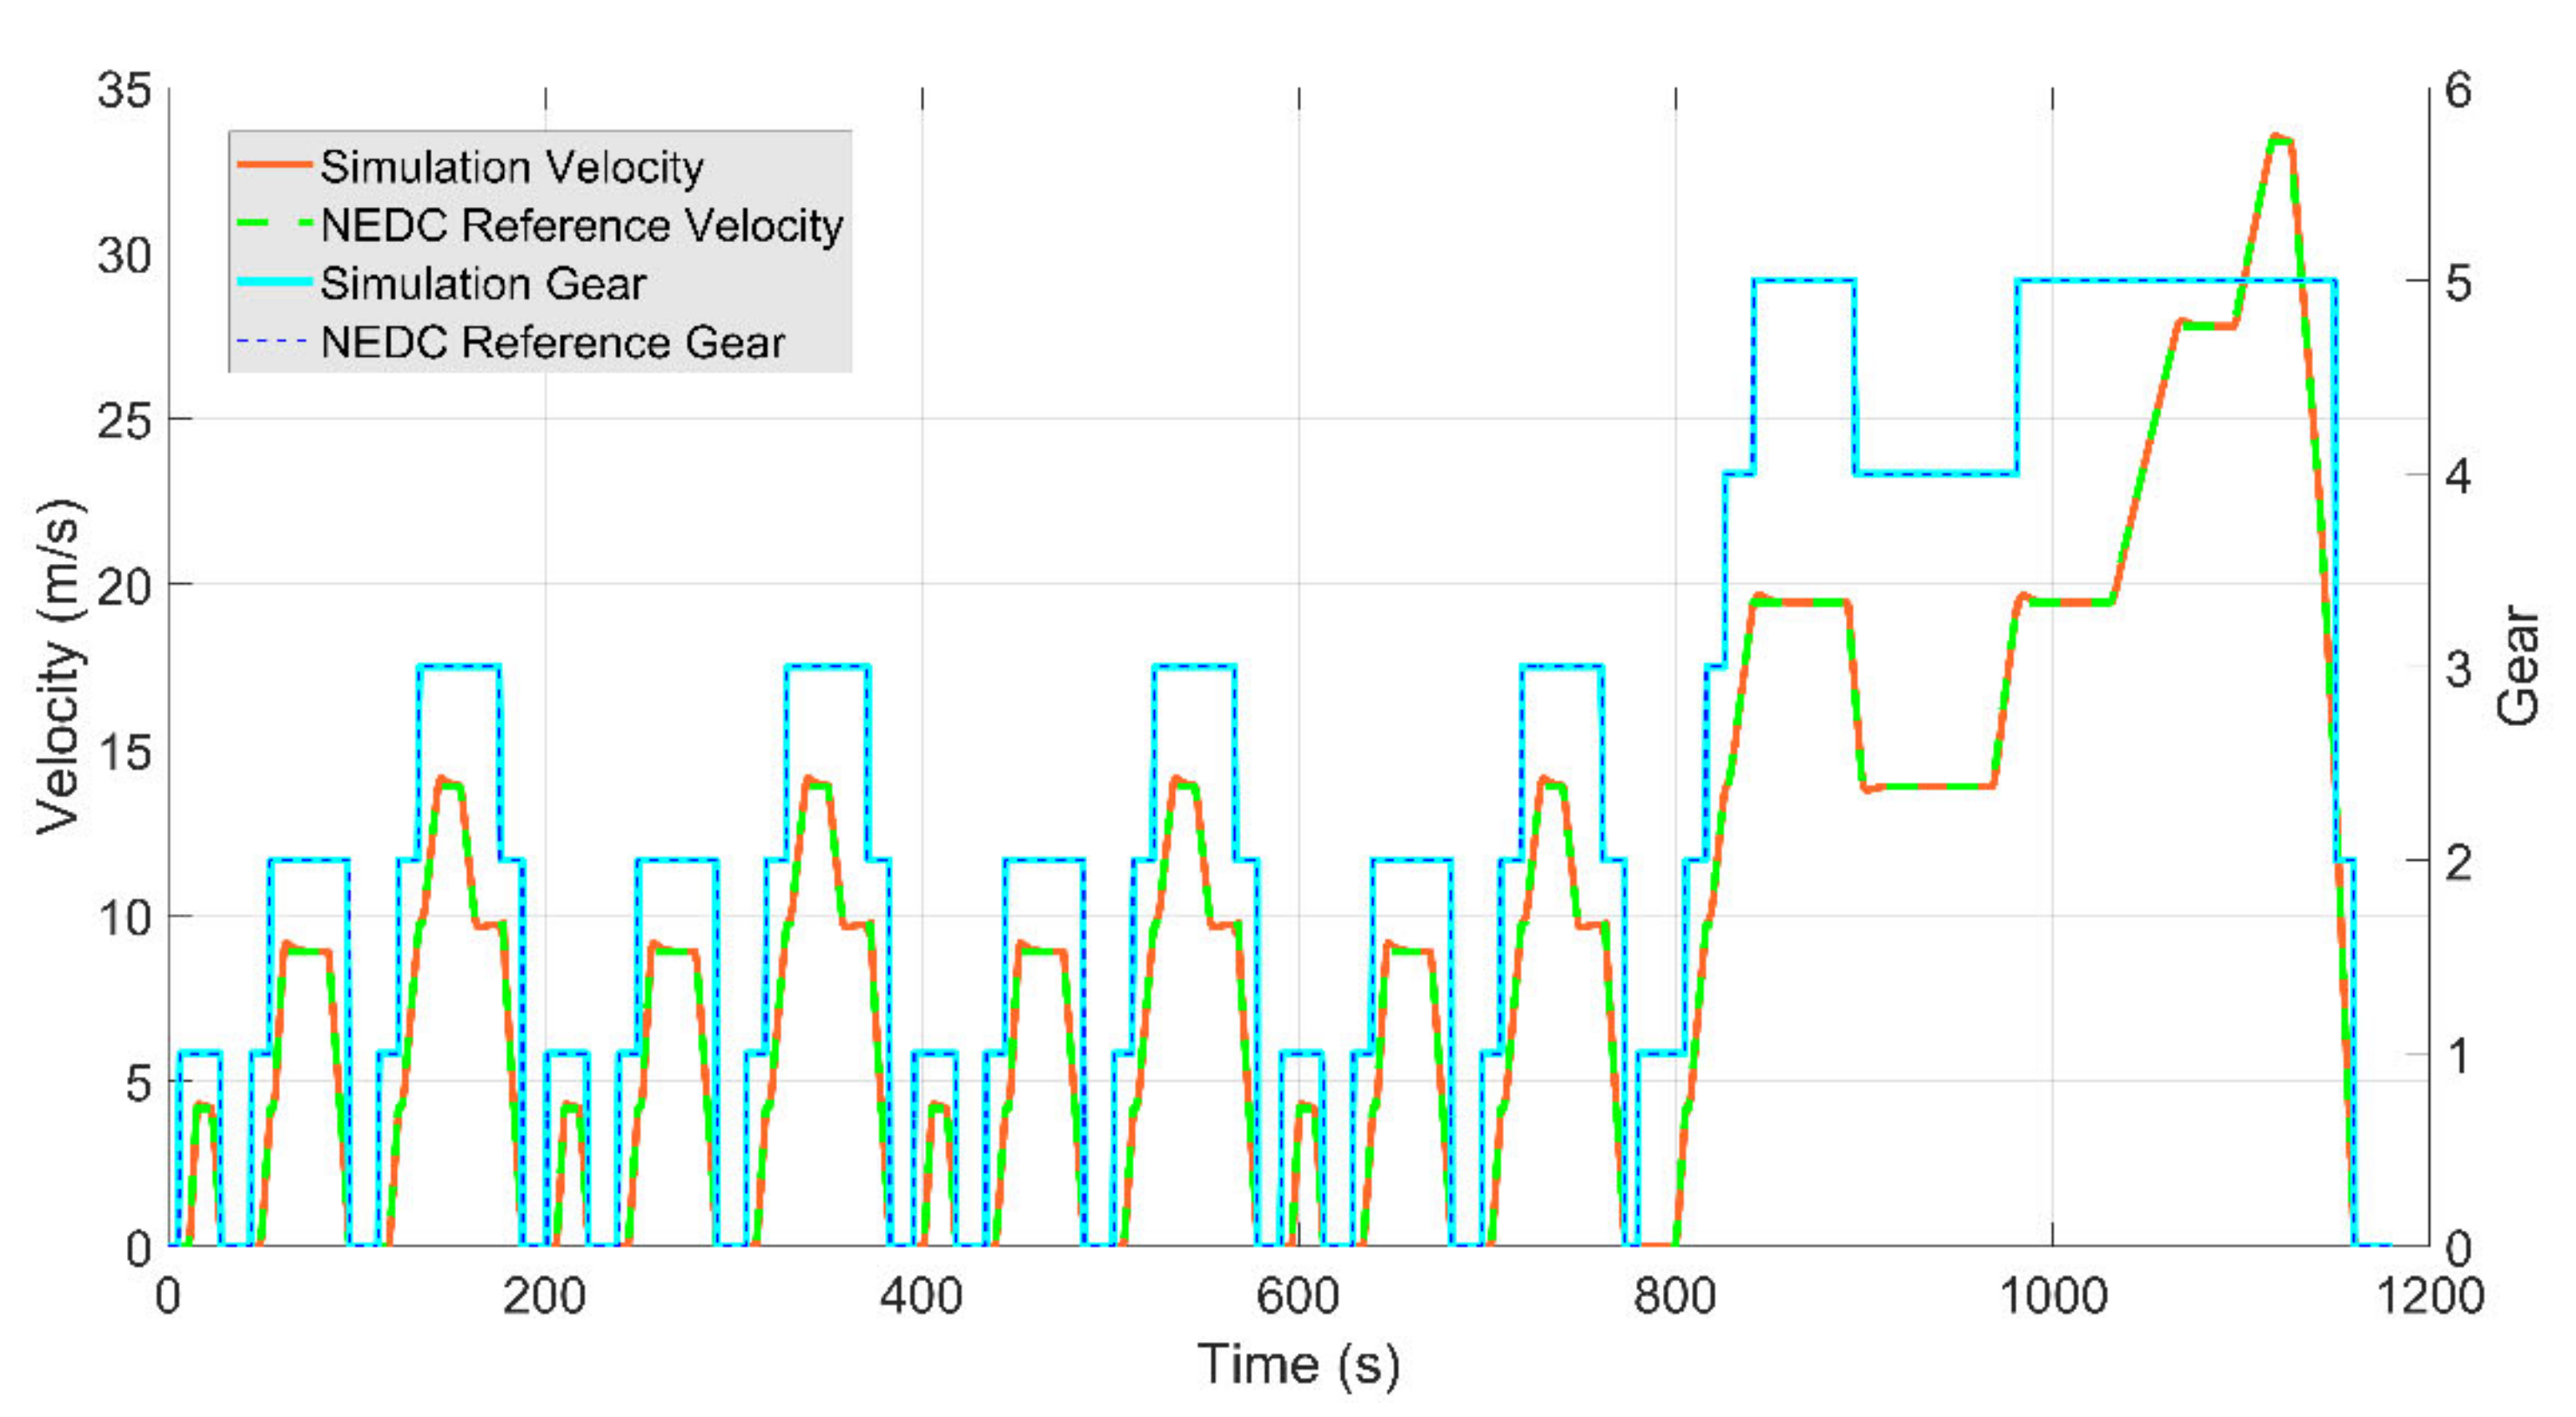
The fuel consumed at the end of the procedure is quite similar in both situations, with 711.00 g for the experimental data and 706.56 g for the simulation one. The percentage error is −0.62% that confirms the quality of the model. Simulated and experimental instantaneous fuel consumption are quite similar too, except for the first 230 s where the (3) is operating. Figure 5 shows the correlation between the NEDC velocity profile and vehicle velocity. PI control can manage the clutch, brake, and accelerator pedal properly.
Figure 5.
Speed profile and actual gear in simulation.
3. Data Collection and Processing
The same datasets presented by Previti et al. [27] were used in this study. Data collection starts with traveling road sections within the city of Messina. During the routes’ execution, the TrackAddict application recorded the vehicle’s speed profile while Google Maps (GM) application showed the level of service of the trip. The measurement campaign allowed the creation of three experimental DCs databases driven in three traffic conditions: High Traffic level (red in GM), Medium Traffic level (orange in GM), and Low Traffic level (green in GM).
Because the final goal is the fuel and energy forecasting comparing, through the use of WLTC, it was necessary to filter the experimental datasets following the same procedure used during the standard cycle’s creation.
Tutuianu et al. [28] discuss the data filtration procedure, which consists of splitting the DCs in idling and short trips. Idle periods are the portions of the driving cycle where the speed is zero. Short trips are the portions contained between two idle periods and where the speed is non-zero, except in the first and last instants of time.
Authors continue applying elimination criteria to the short trips:
- Elimination of short trips with a duration smaller than ten seconds.
- Elimination of short trips with a maximum speed smaller than 1 m/s.
- Elimination of short trips with acceleration higher than 4 m/s2 and smaller than −4.5 m/s2.
After the filtering process, the databases consist of 22 short trips for the Low Traffic level database, 25 short trips for the Medium Traffic level database, and 18 short trips for the High Traffic level database. The 65 short trips represent the speed profiles in different traffic conditions in the city center of Messina. The database containing idle periods was not considered further. This paper aims to create a DC that HEVs’ EMS can use to predict energy and fuel consumption. Since HEVs are equipped with start and stop systems, the power and fuel consumption during idle times are zero.
For each ST belonging to each database, the following quantities were calculated:
- Duration.
- Traveled distance.
- Maximum speed.
- Arithmetic mean of the speed.
- Distance weighted average of speed.
- Distance weighted average of positive acceleration.
- Distance weighted average of negative acceleration.
- Relative Positive Acceleration (RPA).
Equation (4) gives arithmetic mean of the speed for each short trip.
Vm = ∑ vi/nvi
Being vi the instantaneous velocity of short trip, expressed in m/s, and nvi the number of measurements. Equation (5) gives the distance-weighted average of speed.
Vw = ∑ vi·(di − di−1)/∑(di − di−1)
The subscript i represents the time instant and di the distance traveled at the correspondent time instant. Distance weighted average acceleration is given by Equation (6).
aw = ∑ ai·(di − di−1)/∑(di − di−1)
In which ai represents the acceleration at the given time instant and the term (di − di−1) is the partial distance; the equation was applied to both positive and negative accelerations. Equation (7) gives the value of RPA.
RPA = [∫(vi·ai+)∙dt]/x
With being ai+ the positive acceleration and x being the total trip distance.
The eight parameters were extracted from the five short trips of the low section of the WLTC too. Only the low section was considered because experimental speed profiles were only available for urban routes.
The parameters were processed using the method of minimum distances already applied by Brusca et al. [29], in order to assign each short trip of the WLTC to a corresponding traffic level. The procedure consists of calculating the geometrical centroid for each traffic level class considering the parameters as geometrical coordinates. In this way, each short trip of the WLTC, with its corresponding parameters, was assigned to the most appropriate class by considering the shortest Euclidean distance from its centroid.
The proposed method assigned the first and the third ST of WLTC as medium traffic level, the second one as low traffic level, and the fourth and the fifth as high traffic level.
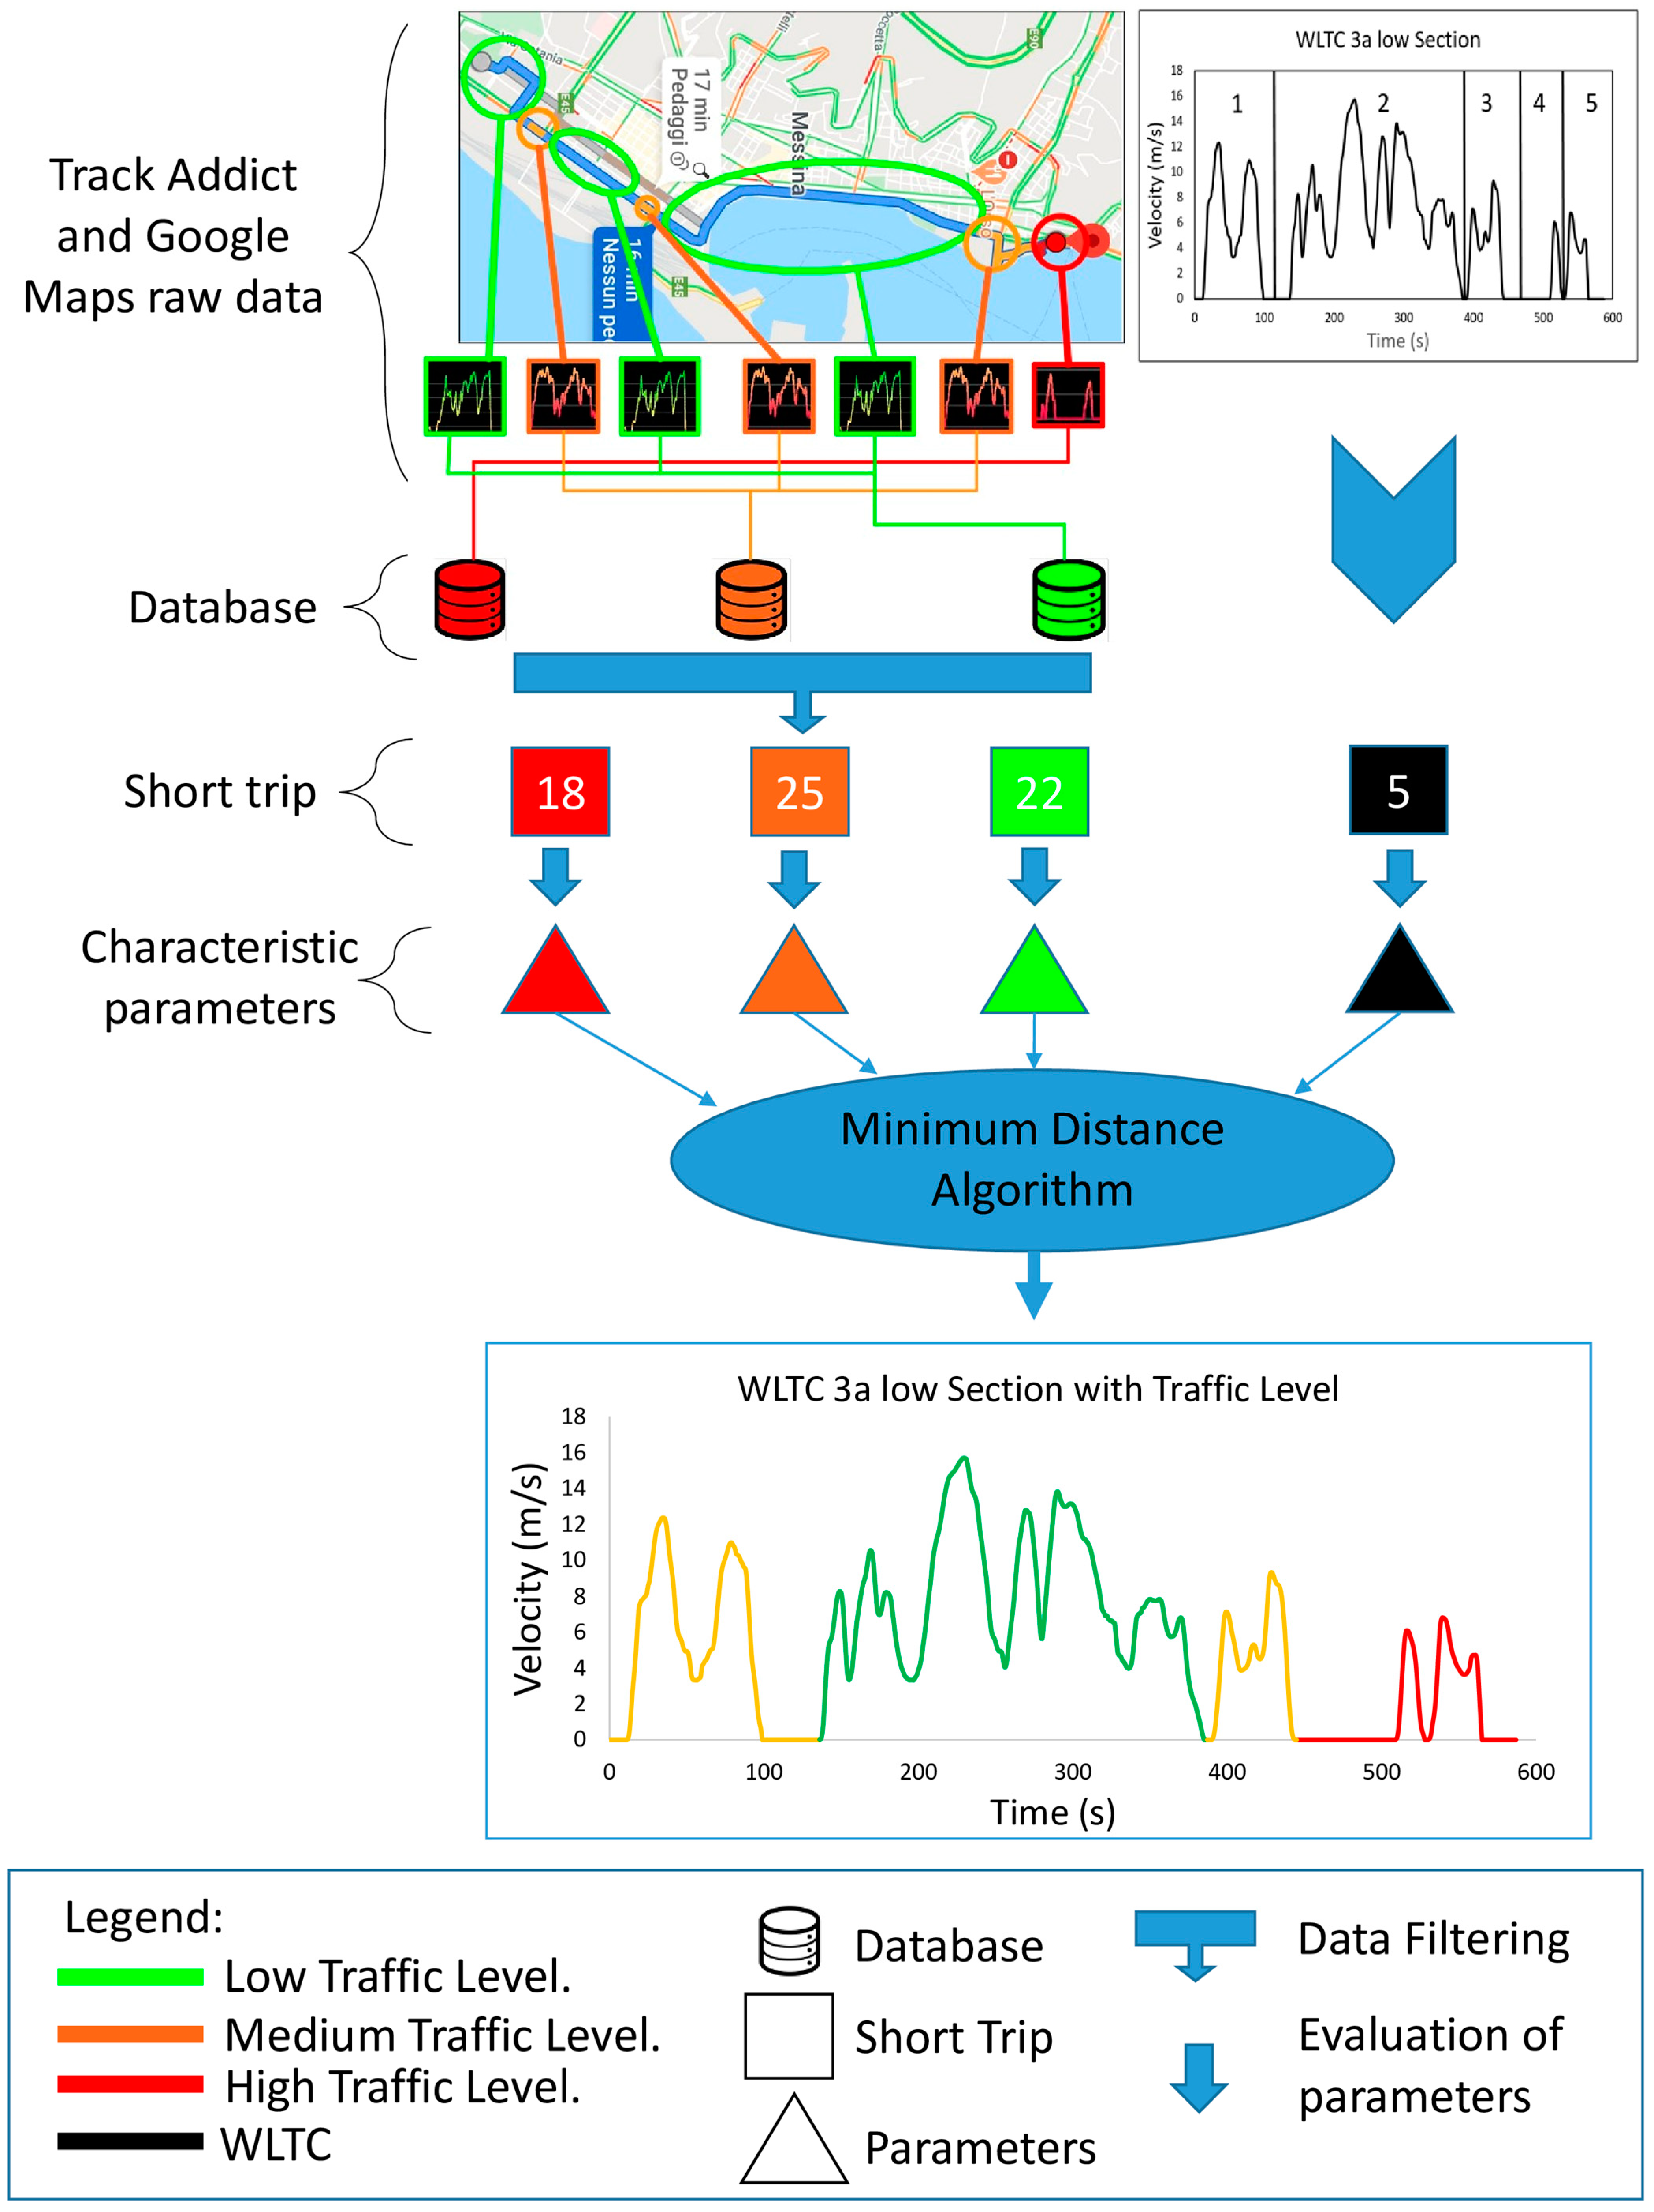
Figure 6 shows the workflow followed, from raw data to the assignment of traffic levels to the WLTC low section.
Figure 6.
Data acquisition, filtering, and analysis process.
4. Simulations
Section 2 describes the numerical model used for the simulation. In the maximum acceleration validation procedure, the shifting strategy was defined by the experimental tests, while in the NEDC simulation the standard procedure provided the shift profile. A gear-change profile was not available for real driving cycles, so a shifting strategy had to be defined to conduct the simulations. The new strategy performs the gear upshifting at 3000 rpm of engine speed and the gear downshifting at 1250 rpm. The strategy allows obtaining a good range of operating points and efficiency, considering that the lowest BSFC values are between 2000 and 3000 rpm of engine speed [30]. The gear change duration remained 0.5 s, as well as the launching speed remained at 1000 rpm. The fuel consumption and energy demand were set to zero in the idling period, assuming that the car is equipped with a Start and Stop system, which is common in new-generation cars.
The forecasting method refers to Google Maps information: the distance to drive and the trip’s traffic status once defining the route’s starting and arrival point. The 65 short trips discussed in the previous chapter were reprocessed to replicate GM information and real drive condition. The STs were arranged randomly, using the MatLab (Mathworks, Natick, MA, USA) function “rand”, and organized into groups with ten ST. The arrangement led to the creation of six driving cycles consisting of 10 short trips and one driving cycle consisting of 5 short trips. Lastly, all the short trips, organized according to an increasing traffic level (from low to high traffic), formed the eighth driving cycle. For the eight driving cycles obtained, the distance covered and traffic level distribution were known in each time instant that is the information provided by Google Maps. The eight DCs were used to obtain the reference fuel and energy consumption value during the execution of road routes in Messina.
The knowledge of the distance to drive in different traffic conditions made it possible to construct the driving cycle to be used for fuel and energy prediction. It was sufficient to reiterate or to interrupt the WLTC short trips, respecting the assigned traffic status, until they cover the same distance as real ones.
By having the eight real driving cycles and the eight constructed ones, it was possible to calculate the real and predicted fuel consumption and energy expenditure. First, a simulation was conducted in which the driver performed the experimental cycles, evaluating the reference fuel and energy value. In the second simulation, the driver performed the driving profiles obtained from the repetition of the WLTC short trips and provided the predicted fuel and energy values. Table 3 shows the results of simulations. The first column contains the driving cycle reference number (one to eight), the second column contains the level of service distribution of each ST, and the third column shows the distance traveled in each DC. The fourth and the fifth columns contain the prediction of energy and fuel consumption accuracy, as percentage error, evaluated by Equations (8) and (9).
ε% energy = (energywltc-energyexp)/energyexp∙100
ε% fuel = (fuelwltc-fuelexp)/fuelexp∙100
Table 3.
Results. Each square is a short trip with a traffic level: red for high, orange for medium, green for low.
The average of the absolute values of percentage errors is 3.89% for fuel consumption, increasing to 6.80% in the energy forecast. In cycle number 8, which covers approximately 34 km, the error in energy expenditure is relatively low (−2.36%) and the fuel consumption error is similar to the average. In cycle 4, where the traveled distance is around 2 km, the prediction percentage absolute error decrease and it is lower than the average (1.44% for energy, 3.07% for fuel). The results suggest that on trips where the distance traveled at low traffic levels is predominant, the proposed methodology tends to underestimate the real values (cycles 7 and 8), but the errors remain low. In trips where distances covered at high traffic intensity are predominant, the methodology tends to overestimate the value of energy and fuel consumed.
The results are even more relevant considering that the proposed methodology:
- It only needs as input data the GM’s information; no other device or software is strictly necessary. This aspect makes the methodology extremely economical.
- The algorithm regulating the traffic levels shown by GM is unique and valid in all city centers. This aspect makes the methodology universal.
- The WLTC considers the driving styles of drivers worldwide so that the methodology can be extended to any car driver.
- The prediction accuracy can increase by considering other input information, such as the traffic lights distribution or typical driver’s gear shifting style. The addition of this information requires the use of appropriate infrastructure and sensors, which runs counter to the purpose of the study.
5. Conclusions
The results are promising since the average of the absolute values of percentage errors between the experimental driving cycles and forecast ones is 3.89% for fuel consumption, increasing to 6.80% for energy. The smallest percentage error in energy assessment, in absolute value, is presented in cycle number four (1.44%); for fuel assessment in cycle number five (0.32%). Cycle 5 also presented the highest percentage error in energy assessment (10.39%), while cycle 2 shows the worst fuel assessment (9.33%). The results highlight that the method can predict the considered quantities with an acceptable error (−2.36% relative percentage error for energy, −4.11% relative percentage error for fuel) in long drive city trips. The technique is easy and cheap to implement in a vehicle’s EMS. The input data are universal, so they can be extended to all cities and lend themselves to the use of additional data to improve prediction accuracy. The results show a reasonable accuracy of fuel consumption and energy expenditure prediction related to the methodology detail and complexity. This study can be the basis for further studies. The possibility of predicting the energy expenditure and fuel consumption of a vehicle allows the development of energy management systems for HEVs which may:
- -
- Manage the energy reserve to allow full electric travel to drive in Limited Traffic Zone (ZTL) or local air pollution minimization.
- -
- Increase the life cycle of energy reserves (usually batteries) by reducing maintenance costs and disposal problems.
- -
- Optimize the efficiency of powertrain use by reducing fuel consumption and pollutant emissions.
Author Contributions
Conceptualization, A.G. and S.B.; methodology, A.G., S.B., F.F., and U.P.; software, U.P.; writing—original draft preparation, A.G., S.B., F.F., and U.P.; writing—review and editing, A.G., S.B., F.F., and U.P.; supervision, A.G. and S.B. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Data sharing not applicable.
Acknowledgments
The authors are grateful to AVL Italia for providing the simulation suites, including AVL Cruise-M. They are pleased to collaborate with the company and to be able to exchange information and expertise.
Conflicts of Interest
The authors declare no conflict of interest.
Appendix A
Table A1 collects the numerical values of BSFC map used to evaluate fuel consumption.
Table A1.
BSFC map numerical values function of engine speed and engine torque.
References
- Zhou, Y.; Ravey, A.; Péra, M. A survey on driving prediction techniques for predictive energy management of plug-in hybrid electric vehicles. J. Power Sour. 2019, 412, 480–495. [Google Scholar] [CrossRef] [Scilit]
- Sciarretta, A.; Guzzella, L. Vehicle Propulsion Systems: Introduction to Modeling and Optimization, 3rd ed.; Springer: Berlin/Heidelberg, Germany, 2005. [Google Scholar]
- Bagwe, R.M.; Byerly, A.; dos Santos, E.C., Jr.; Ben-Miled, Z. Adaptive Rule-Based Energy Management Strategy for a Parallel HEV. Energies 2019, 12, 4472. [Google Scholar] [CrossRef] [Scilit]
- Wu, J.; Wei, Z.; Liu, K.; Quan, Z.; Li, Y. Battery-Involved Energy Management for Hybrid Electric Bus Based on Expert-Assistance Deep Deterministic Policy Gradient Algorithm. IEEE Trans. Veh. Technol. 2020, 69, 12786–12796. [Google Scholar] [CrossRef] [Scilit]
- Fang, L.; Qin, S.; Xu, G.; Li, T.; Zhu, K. Simultaneous Optimization for Hybrid Electric Vehicle Parameters Based on Multi-Objective Genetic Algorithms. Energies 2011, 4, 532–544. [Google Scholar] [CrossRef] [Scilit]
- Wu, J.; Wei, Z.; Li, W.; Wang, Y.; Li, Y.; Sauer, D. Battery Thermal- and Health-Constrained Energy Management for Hybrid Electric Bus based on Soft Actor-Critic DRL Algorithm. IEEE Trans. Ind. Inform. 2020. [Google Scholar] [CrossRef] [Scilit]
- Wang, R.; Lukic, S.M. Review of Driving Conditions Prediction and Driving Style Recognition Based Control Algorithms for Hybrid Electric Vehicle. In Proceedings of the 2011 IEEE Vehicle Power and Propulsion Conference, Chicago, IL, USA, 6–9 September 2011. [Google Scholar] [CrossRef] [Scilit]
- Ericson, E. Independent Driving Pattern Factors and Their Influence on Fuel-Use and Exhaust Emission Factors. Transp. Res. Part D Transp. Environ. 2001, 6, 325–345. [Google Scholar] [CrossRef] [Scilit]
- Xi, H.; Ying, T.; Xingui, H. An intelligent multi-feature statistical approach for discrimination of driving conditions of hybrid electric vehicle. In Proceedings of the International Joint Conference on Neural Networks, Atlanta, GA, USA, 14–19 June 2009. [Google Scholar] [CrossRef] [Scilit]
- Chen, Z.; Kiliaris, L.; Murphey, Y.L.; Masrur, A. Intelligent power management in SHEV based on roadway type and traffic congestion levels. In Proceedings of the Vehicle Power and Propulsion Conference, Dearborn, MI, USA, 7–10 September 2009. [Google Scholar] [CrossRef] [Scilit]
- Langari, R.; Won, J. Intelligent Energy Management Agent for a Parallel Hybrid Vehicle—Part I I: System Architecture and Design of the Driving Situation Identification Process. IEEE Trans. Veh. Technol. 2005, 54, 925–934. [Google Scholar] [CrossRef] [Scilit]
- Jeon, S.; Park, Y.; Lee, J. Multi-Mode Driving Control of a Parallel Hybrid Electric Vehicle Using Driving Pattern Recognition. J. Dyn. Sys. Meas. Control. 2002, 124, 141–149. [Google Scholar] [CrossRef] [Scilit]
- Han, L.; Jiao, X.; Zhang, Z. Recurrent Neural Network-Based Adaptive Energy Management Control Strategy of Plug-In Hybrid Electric Vehicles Considering Battery Aging. Energies 2020, 13, 202. [Google Scholar] [CrossRef] [Scilit]
- Liu, H.; Wang, C.; Zhao, X.; Guo, C. An Adaptive-Equivalent Consumption Minimum Strategy for an Extended-Range Electric Bus Based on Target Driving Cycle Generation. Energies 2018, 11, 1805. [Google Scholar] [CrossRef] [Scilit]
- Johannesson, L.; Asbogard, M.; Egardt, B. Assessing the Potential of Predictive Control for Hybrid Vehicle Powertrains Using Stochastic Dynamic Programming. IEEE Trans. Veh. Technol. 2007, 8, 71–83. [Google Scholar] [CrossRef] [Scilit]
- Lin, C.; Peng, H.; Grizzle, J. Stochastic Control Strategy for Hybrid Electric Vehicles. In Proceedings of the 2004 American Control Conference, Boston, MA, USA, 30 June–2 July 2004; Volume 5, pp. 4710–4715. [Google Scholar] [CrossRef] [Scilit]
- Chaofeng, P.; Wei, W.; Liao, C.; Long, C.; Limei, W. Driving range estimation for electric vehicles based on driving condition identification and forecast. AIP Adv. 2017, 7, 105206. [Google Scholar] [CrossRef] [Scilit]
- Shen, P.; Zhao, Z.; Zhan, X.; Li, J.; Guo, Q. Optimal energy management strategy for a plug-in hybrid electric commercial vehicle based on velocity prediction. Energy 2018, 155, 838–852. [Google Scholar] [CrossRef] [Scilit]
- Zhang, C.; Vahidi, A.; Pisu, P.; Li, X.; Tennant, K. Role of Terrain Preview in Energy Management of Hybrid Electric Vehicles. IEEE Trans. Veh. Technol. 2010, 59, 1139–1147. [Google Scholar] [CrossRef] [Scilit]
- Qiuming, G.; Yaoyu, L.; Zhong-Ren, P. Optimal power management of plug-in hybrid electric vehicles. IEEE Trans. Veh. Technol. 2008, 57, 3393–3401. [Google Scholar] [CrossRef] [Scilit]
- He, H.; Guo, J.; Zhou, N.; Sun, C.; Peng, J. Freeway Driving Cycle Construction Based on Real-Time Traffic Information and Global Optimal Energy Management for Plug-In Hybrid Electric Vehicles. Energies 2017, 10, 1796. [Google Scholar] [CrossRef] [Scilit]
- Zhang, F.; Xi, J.; Langari, R. Real-Time Energy Management Strategy Based on Velocity Forecasts Using V2V and V2I Communications. IEEE Trans. Veh. Technol. 2017, 18, 416–430. [Google Scholar] [CrossRef] [Scilit]
- Hu, J.; Jiang, X.; Jia, M.; Zheng, Y. Energy Management Strategy for the Hybrid Energy Storage System of Pure Electric Vehicle Considering Traffic Information. Appl. Sci. 2018, 8, 1266. [Google Scholar] [CrossRef] [Scilit]
- Yavasoglu, Y.A.; Tetik, Y.; Gokce, K. Implementation of machine learning based real time range estimation method without destination knowledge for BEVs. Energy 2019, 172, 1179–1186. [Google Scholar] [CrossRef] [Scilit]
- Douglas, K.; Milovanovic, N.; Turner, J.; Blundell, D. Fuel Economy Improvement Using Combined CAI and Cylinder Deactivation (CDA)—An Initial Study; SAE Technical Paper; SAE: Warrendale, PA, USA, 2005; Volume 1, p. 0110. [Google Scholar] [CrossRef] [Scilit]
- Cossalter, V. Motorcycle Dynamics, 2nd ed.; Lulu.com: Morrisville, NC, USA, 2002. [Google Scholar]
- Previti, U.; Brusca, S.; Galvagno, A. Passenger Car Energy Demand Assessment: A New Approach Based on Road Traffic Data. In Proceedings of the 75th National ATI Congress—#7 Clean Energy for all (ATI 2020), E3S Web Conference, Rome, Italy, 15–16 September 2020; Volume 197, p. 05006. [Google Scholar] [CrossRef] [Scilit]
- Tutuianu, M.; Bonnel, P.; Ciuffo, B.; Haniu, T.; Ichikawa, N.; Marotta, A.; Pavlovic, J.; Steven, H. Development of the World-wide harmonized Light duty Test Cycle (WLTC) and a possible pathway for its introduction in the European legislation. Trans. Res. Part D Transp. Environ. 2015, 40, 61–75. [Google Scholar] [CrossRef] [Scilit]
- Brusca, S.; Famoso, F.; Lanzafame, R.; Galvagno, A.; Mauro, S.; Messina, M. Wind farm power forecasting: New algorithms with simplified mathematical structure. AIP Conf. Proc. 2019, 2191, 020028. [Google Scholar] [CrossRef] [Scilit]
- Oglieve, C.J.; Mohammadpour, M.; Rahnejat, H. Optimisation of the vehicle transmission and the gear-shifting strategy for the minimum fuel consumption and the minimum nitrogen oxide emissions. Proc. Inst. Mech. Eng. Part D 2017, 231, 883–899. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2021 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).