Analysis of Surface EMG Signals to Control of a Bionic Hand Prototype with Its Implementation †

Abstract
1. Introduction
1.1. Surface Electromyography sEMG
1.2. Principles of Surface Electromyography (sEMG)
1.3. Importance, Applications, and Evolution of sEMG
1.4. Prior Work on Forearm EMG Signal Analysis
1.5. Signal Processing Techniques for sEMG
1.6. Summary and Motivation
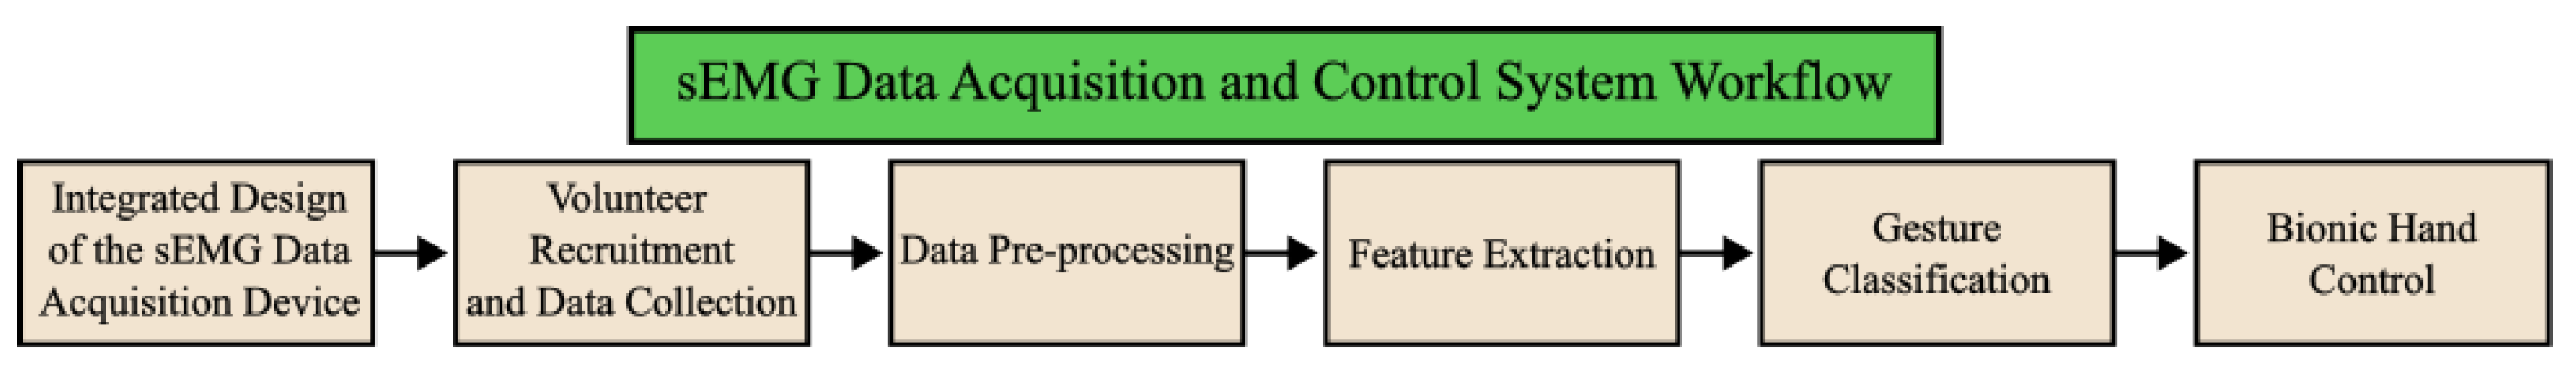
2. Materials and Methods
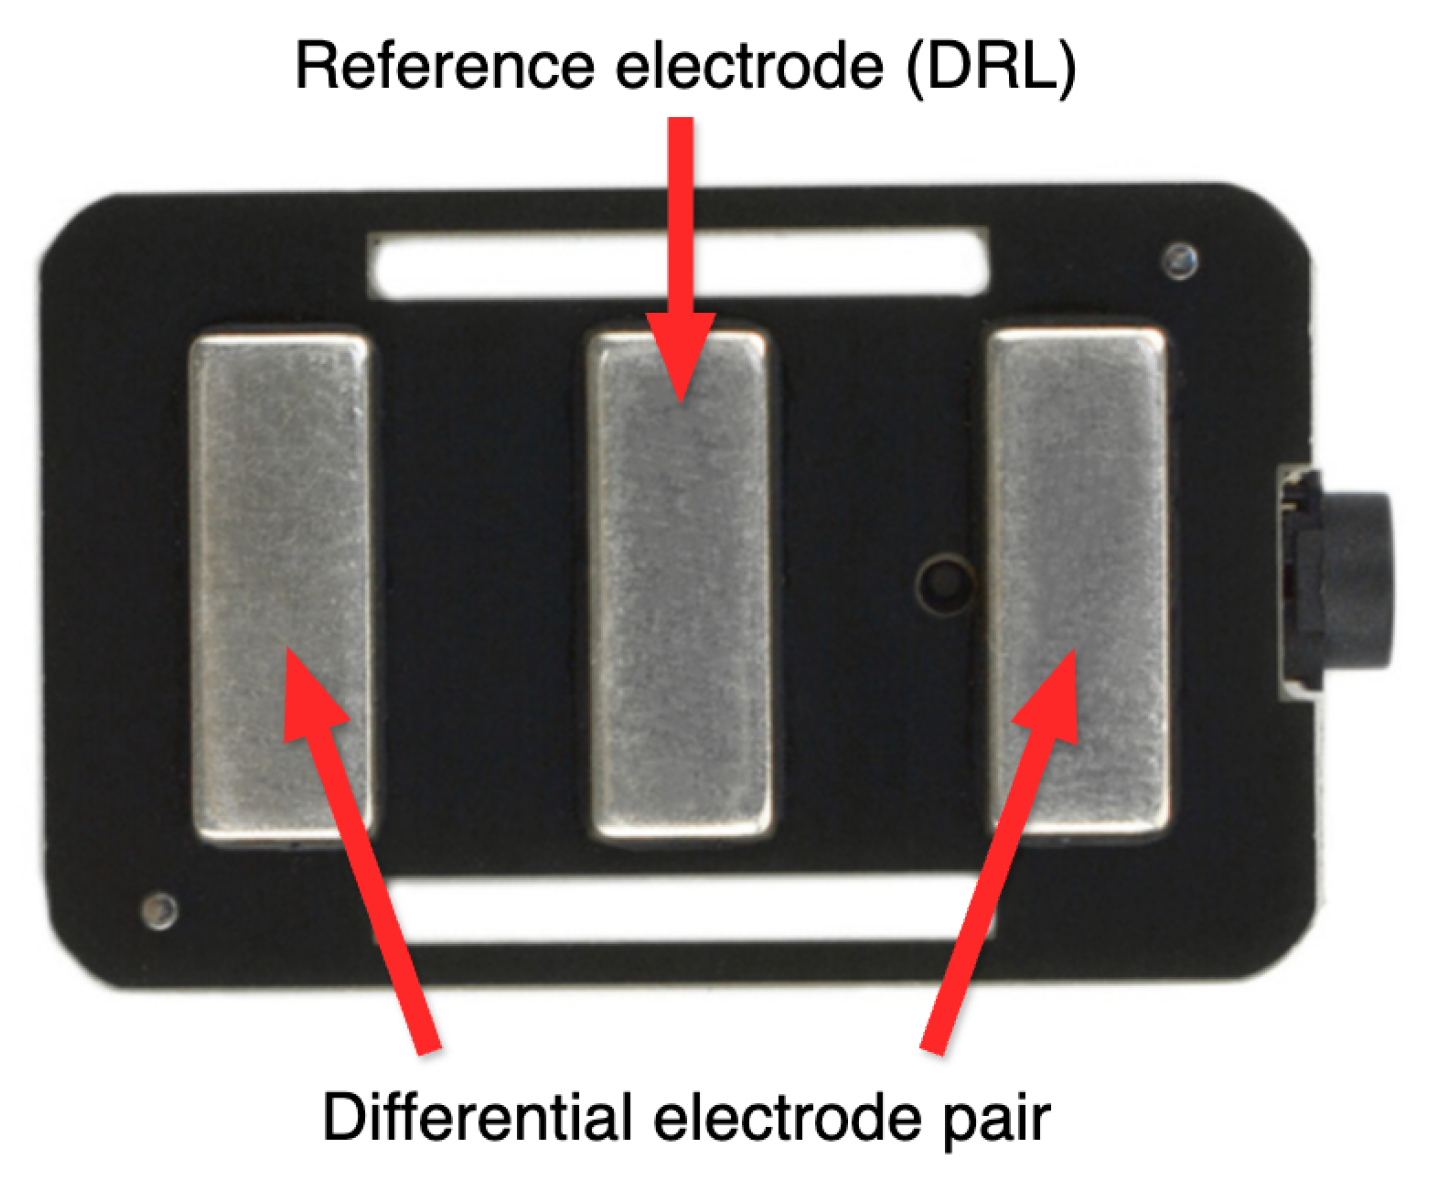
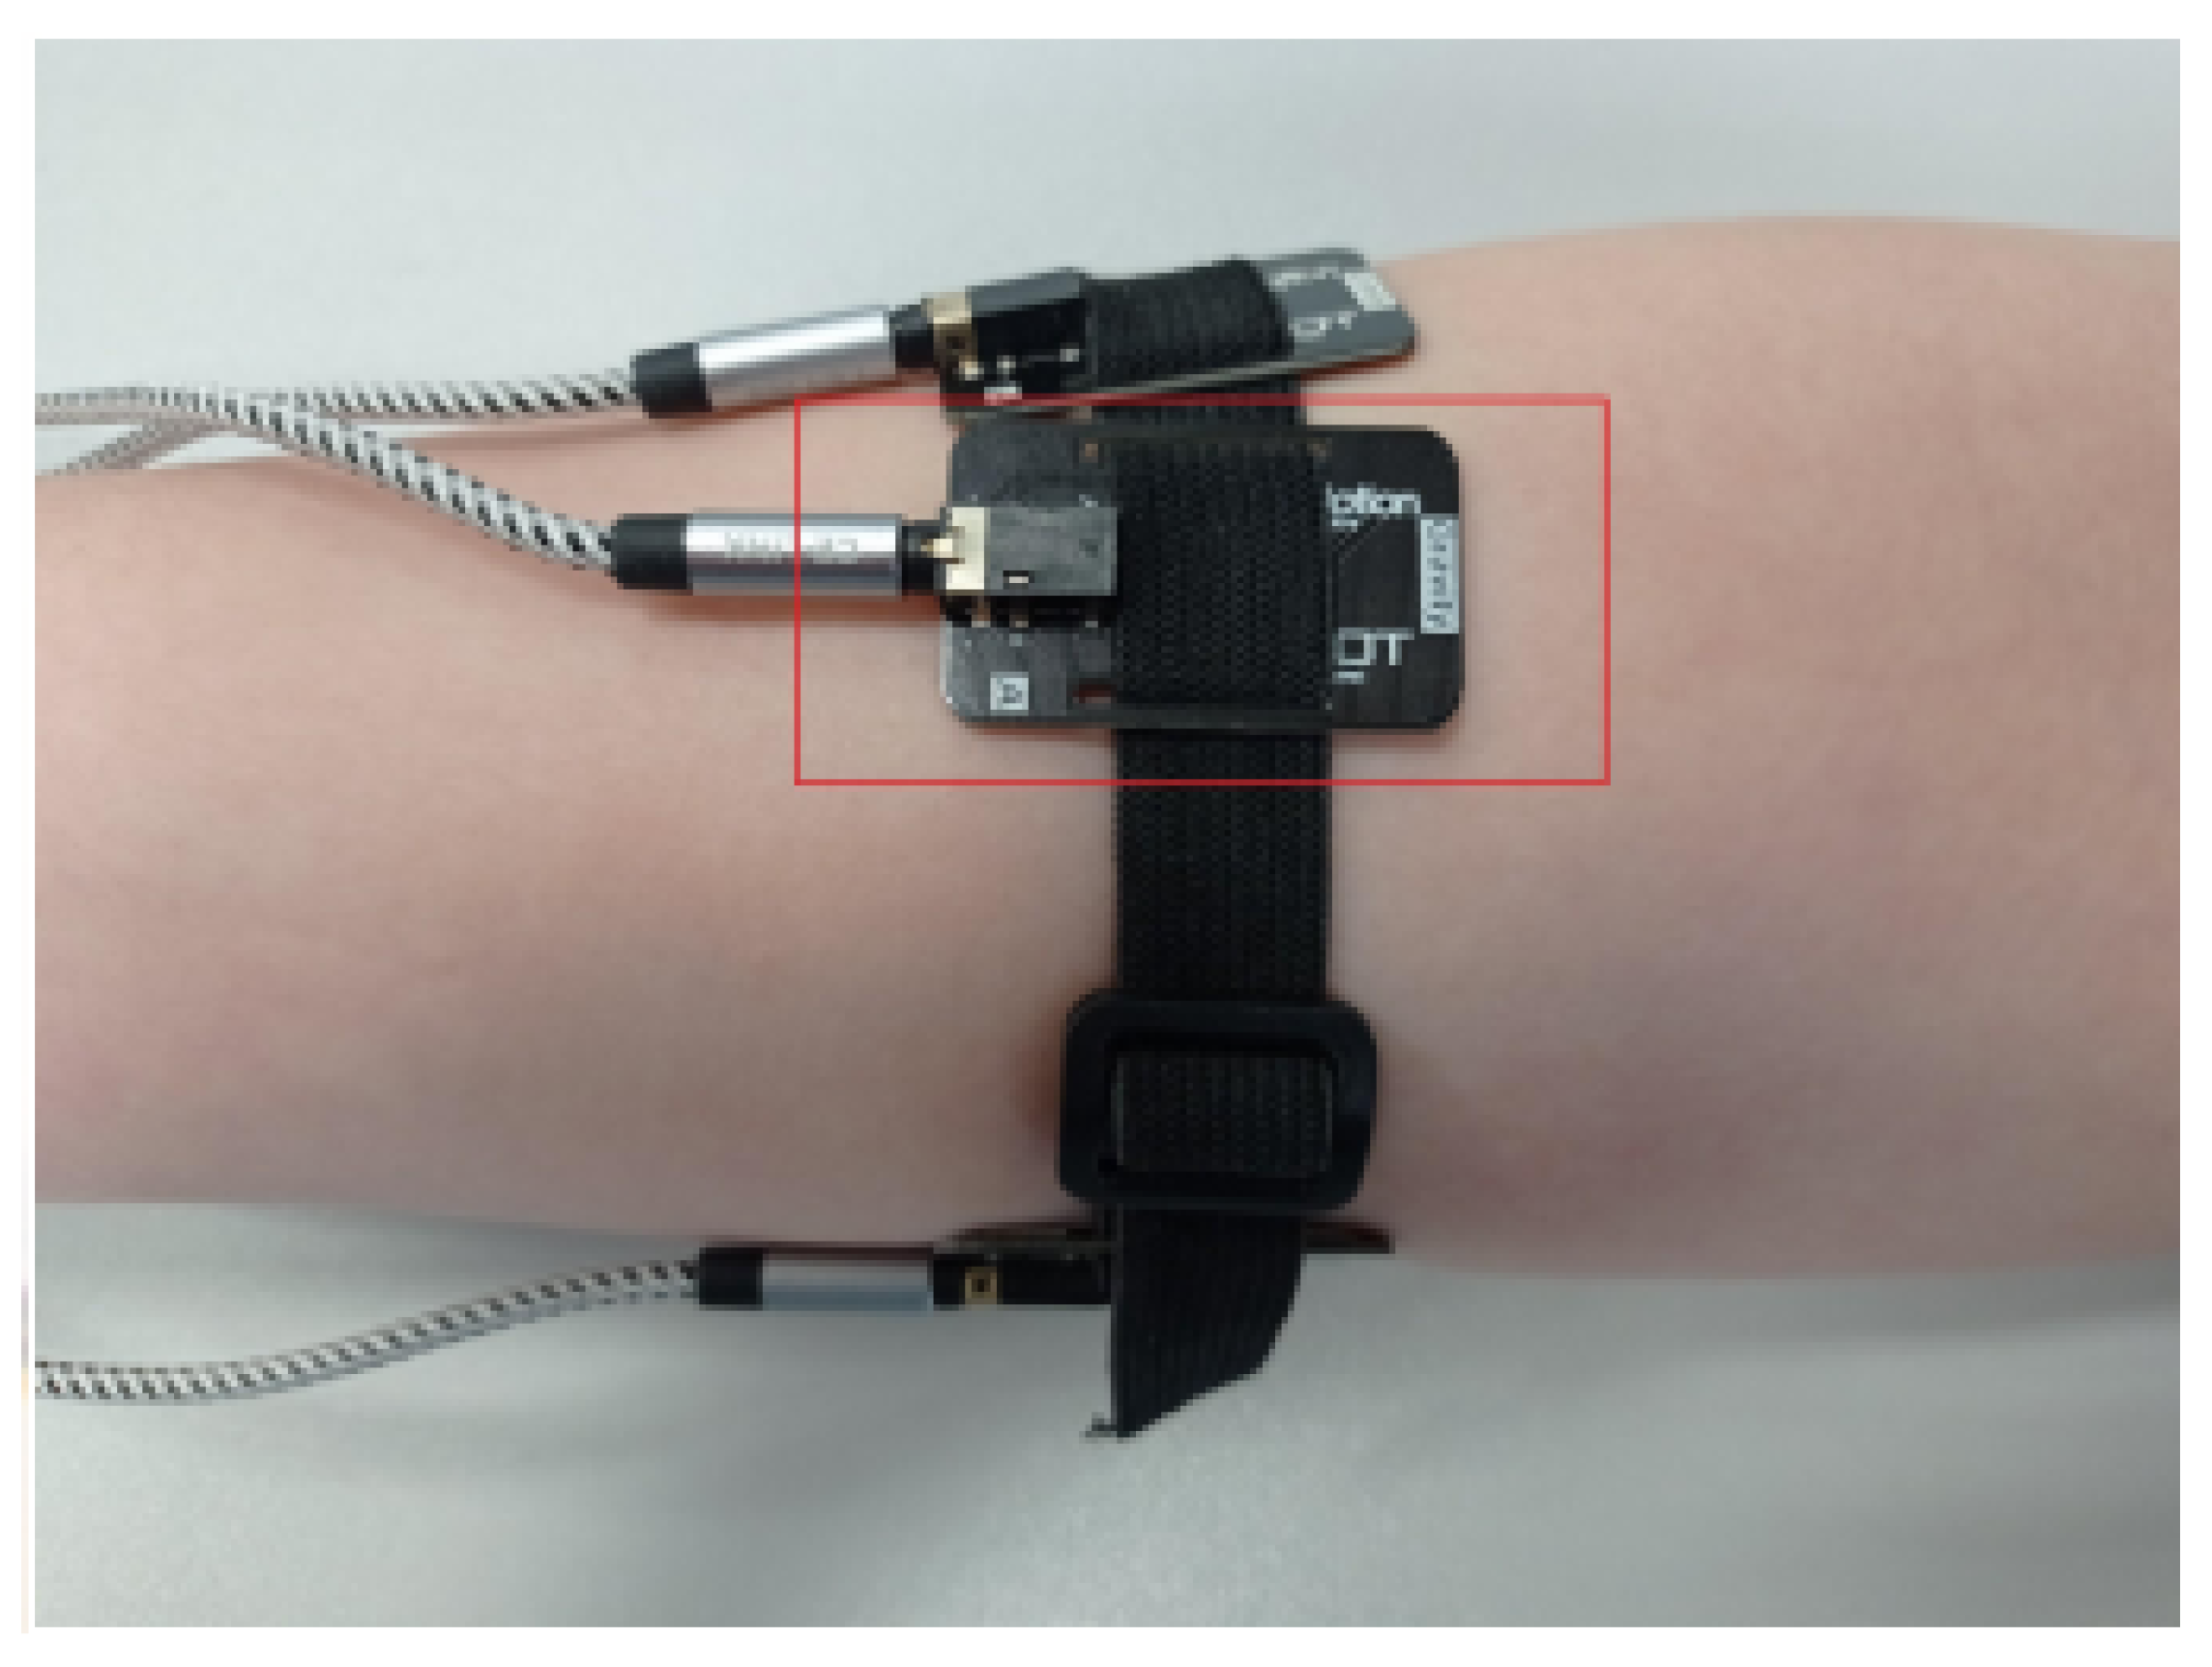
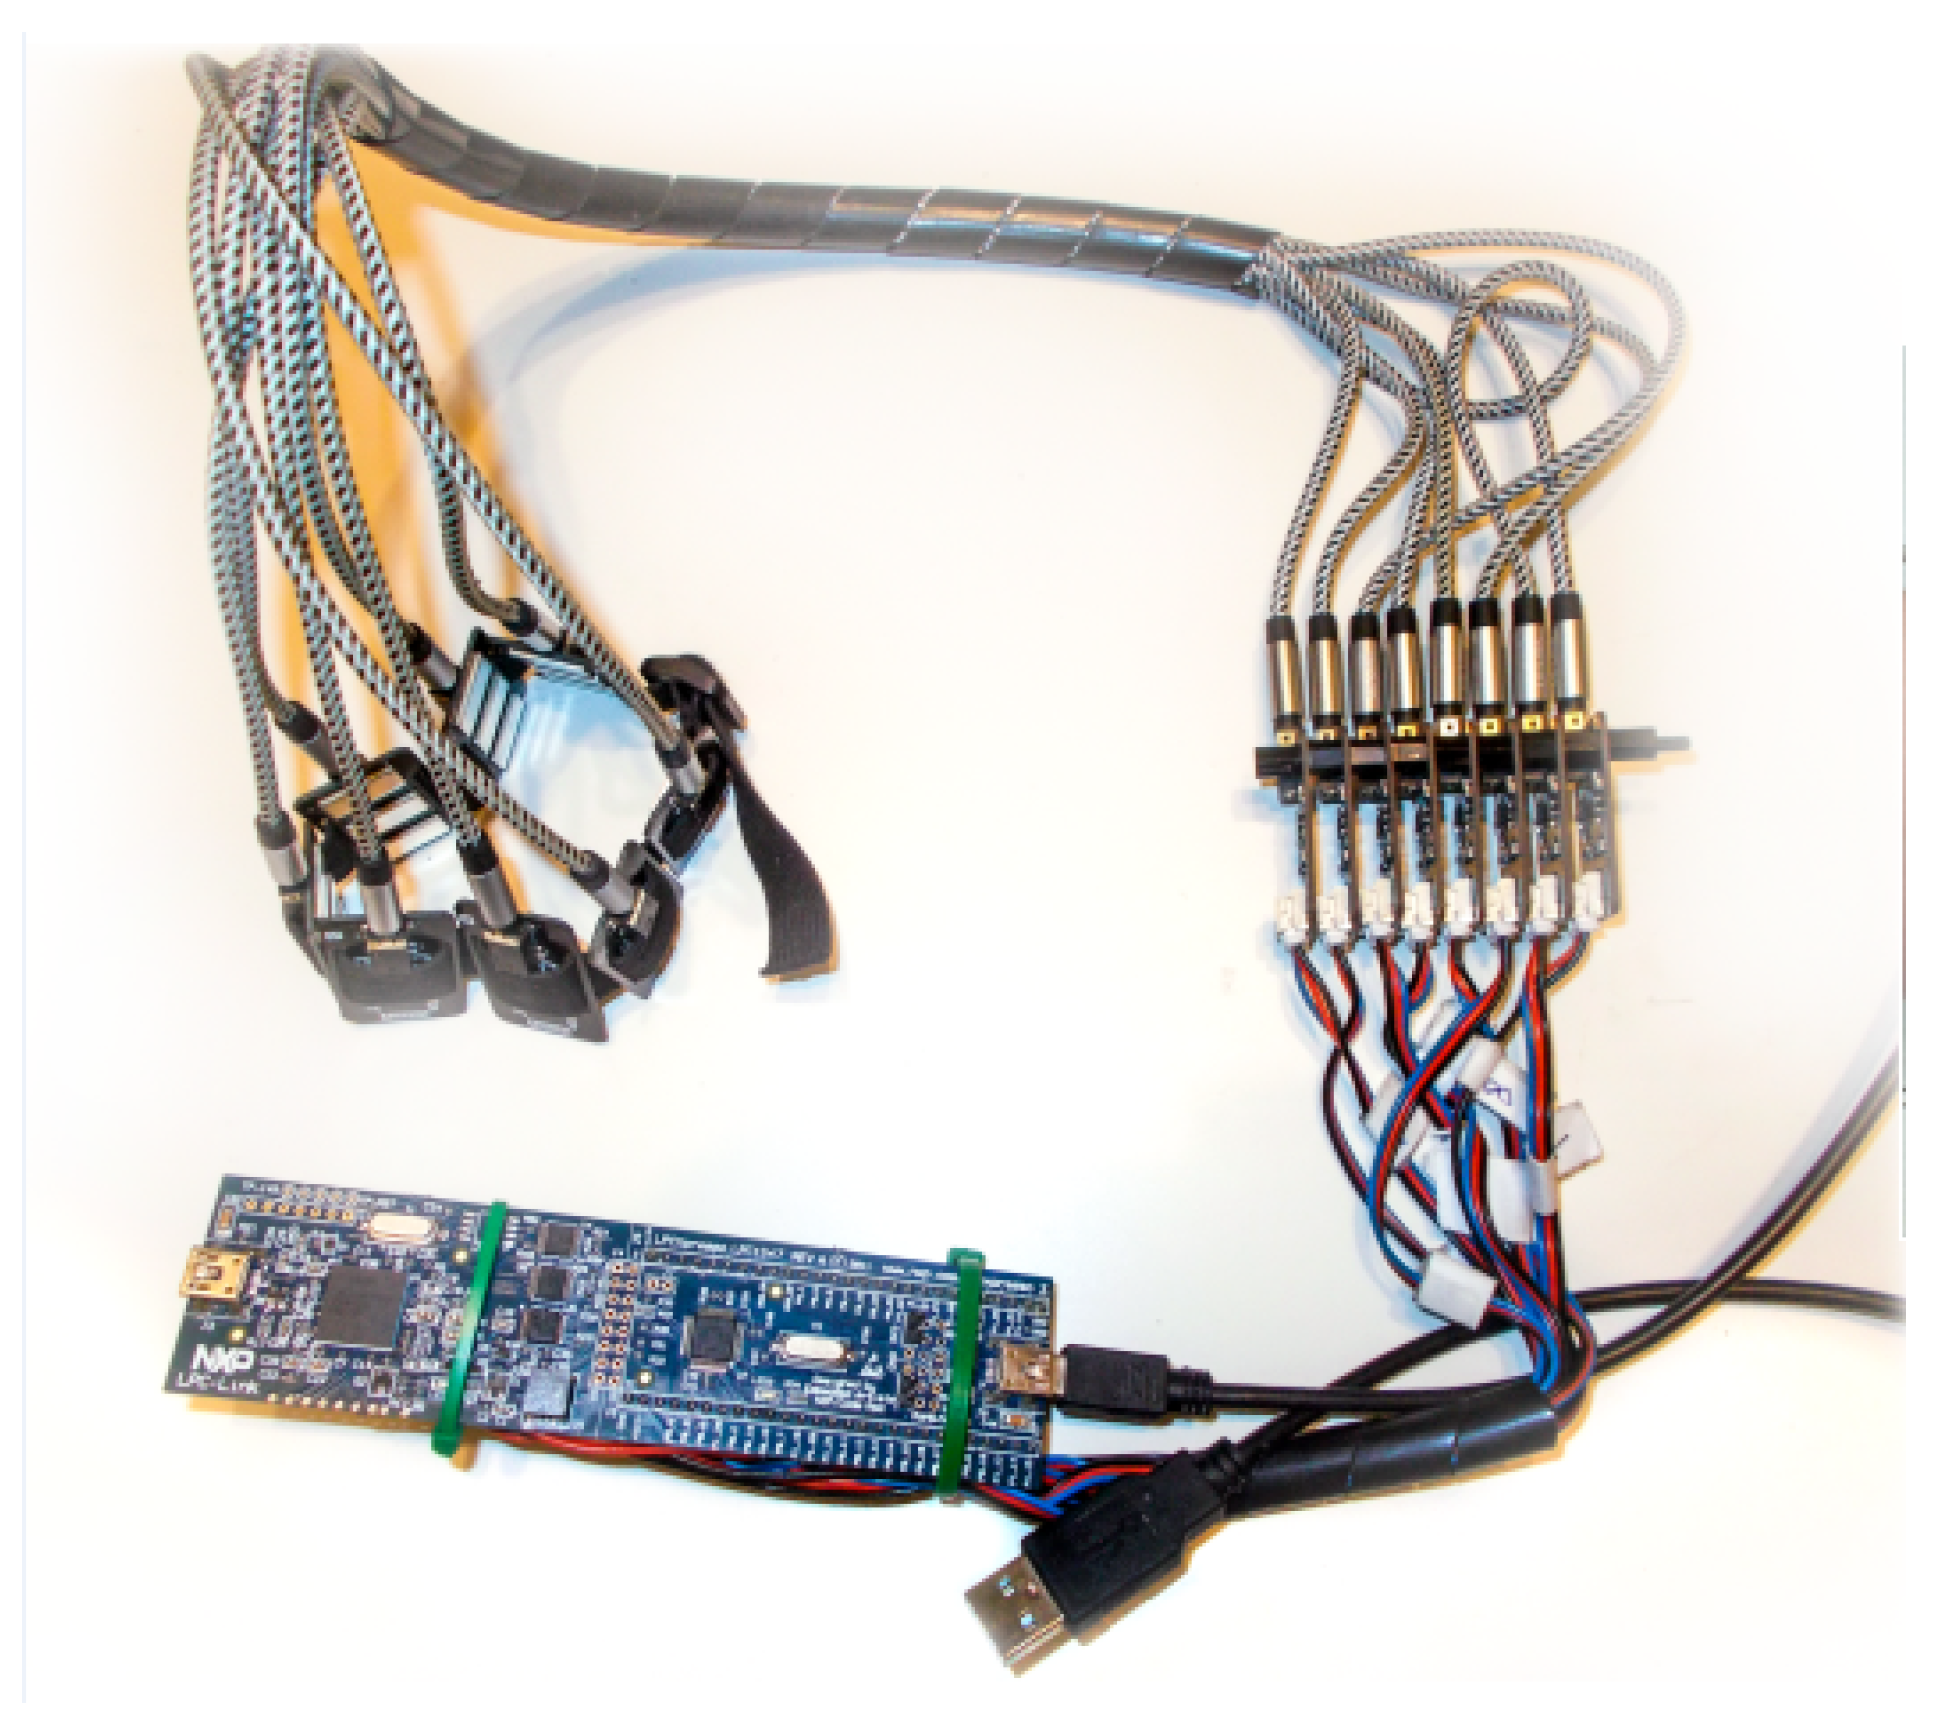
2.1. Gesture Signals Collecting—Hardware
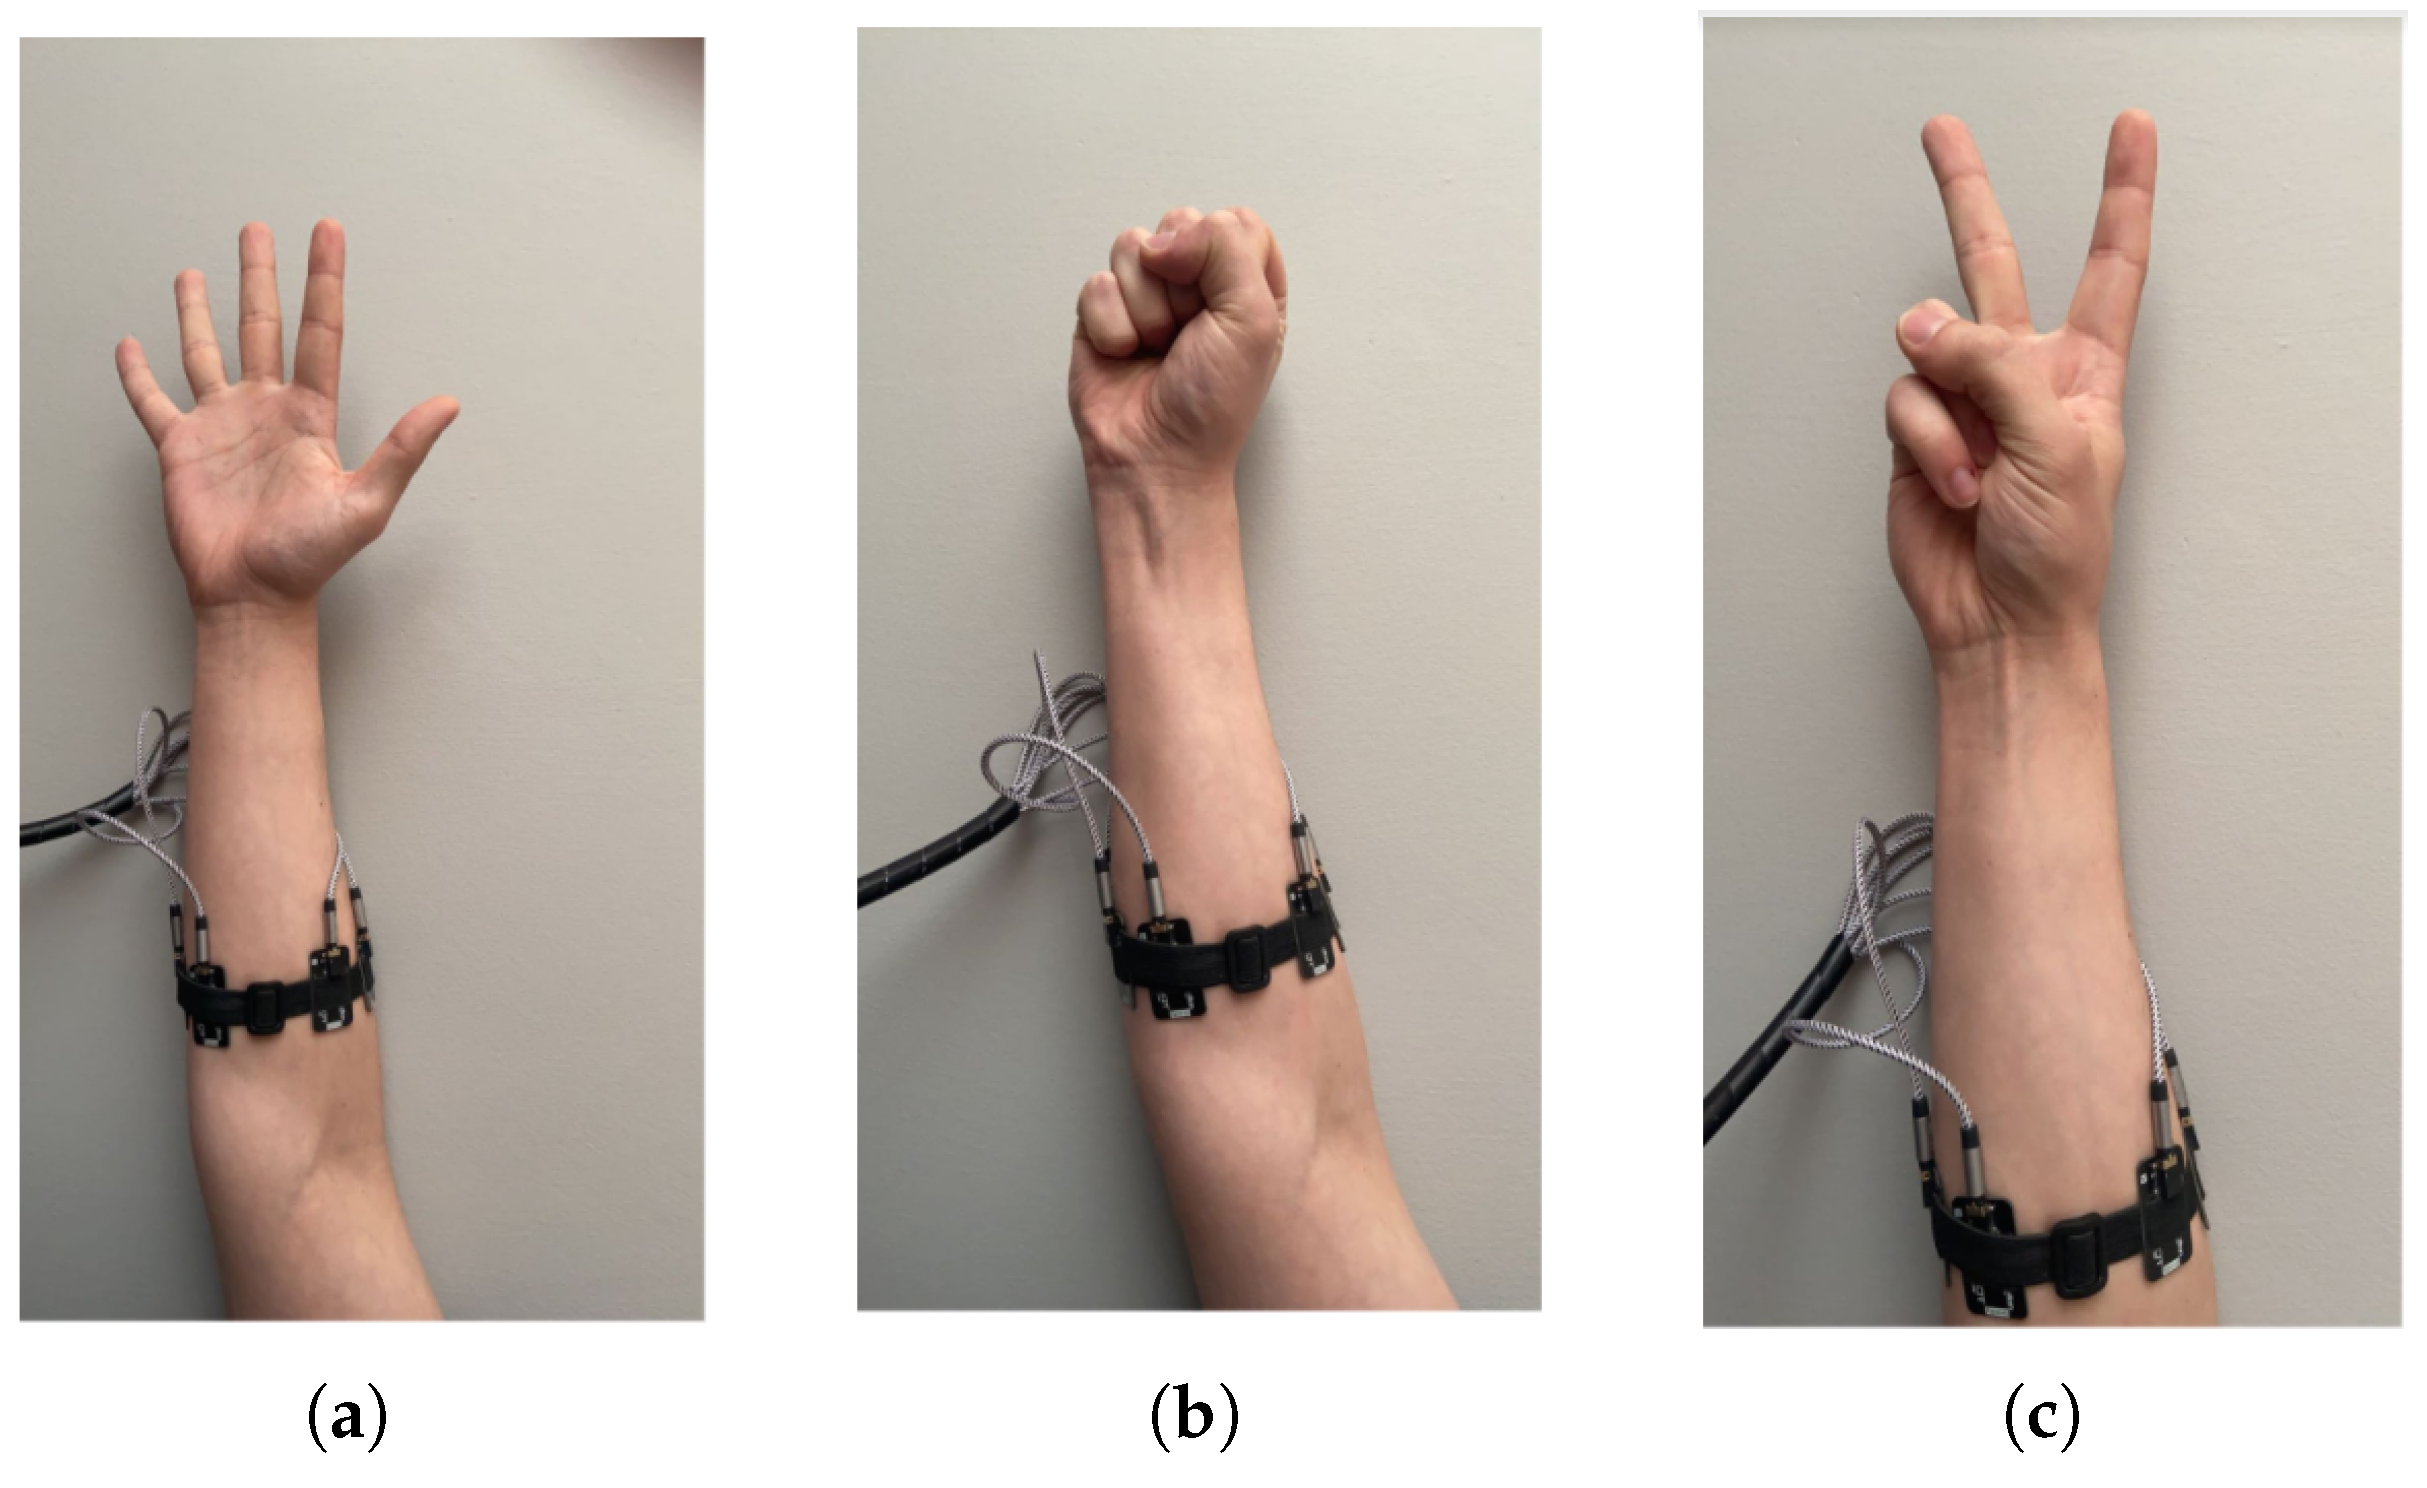
2.2. Collecting sEMG Signal Selected Gestures

2.3. Software
3. Processing EMG Signal Features
3.1. Feature Extraction
3.2. Data Preprocessing
3.3. Building Models
- is the observed value of the dependent variable for the i-th observation;
- is the vector of independent variables for the i-th observation;
- is the intercept term;
- is the vector of regression coefficients for the predictors;
- n is the number of observations;
- p is the number of predictors;
- (lambda) is the regularization parameter (penalty strength), controlling the degree of coefficient shrinkage, where a larger indicates a stronger penalty;
- is the L1 penalty, representing the sum of the absolute values of the coefficients.
- , , , , n, and p have the same meaning as in LASSO;
- (lambda) is the regularization parameter, controlling the overall penalty strength;
- (alpha) is the mixing parameter, in the range of ;
- If , Elastic Net becomes LASSO (L1 penalty only);
- If , Elastic Net becomes Ridge (L2 penalty only);
- For , Elastic Net is a combination of both penalties;
- is the L1 penalty;
- is the L2 penalty (sum of squared coefficients).
4. Implementation Simple Bionic Hand
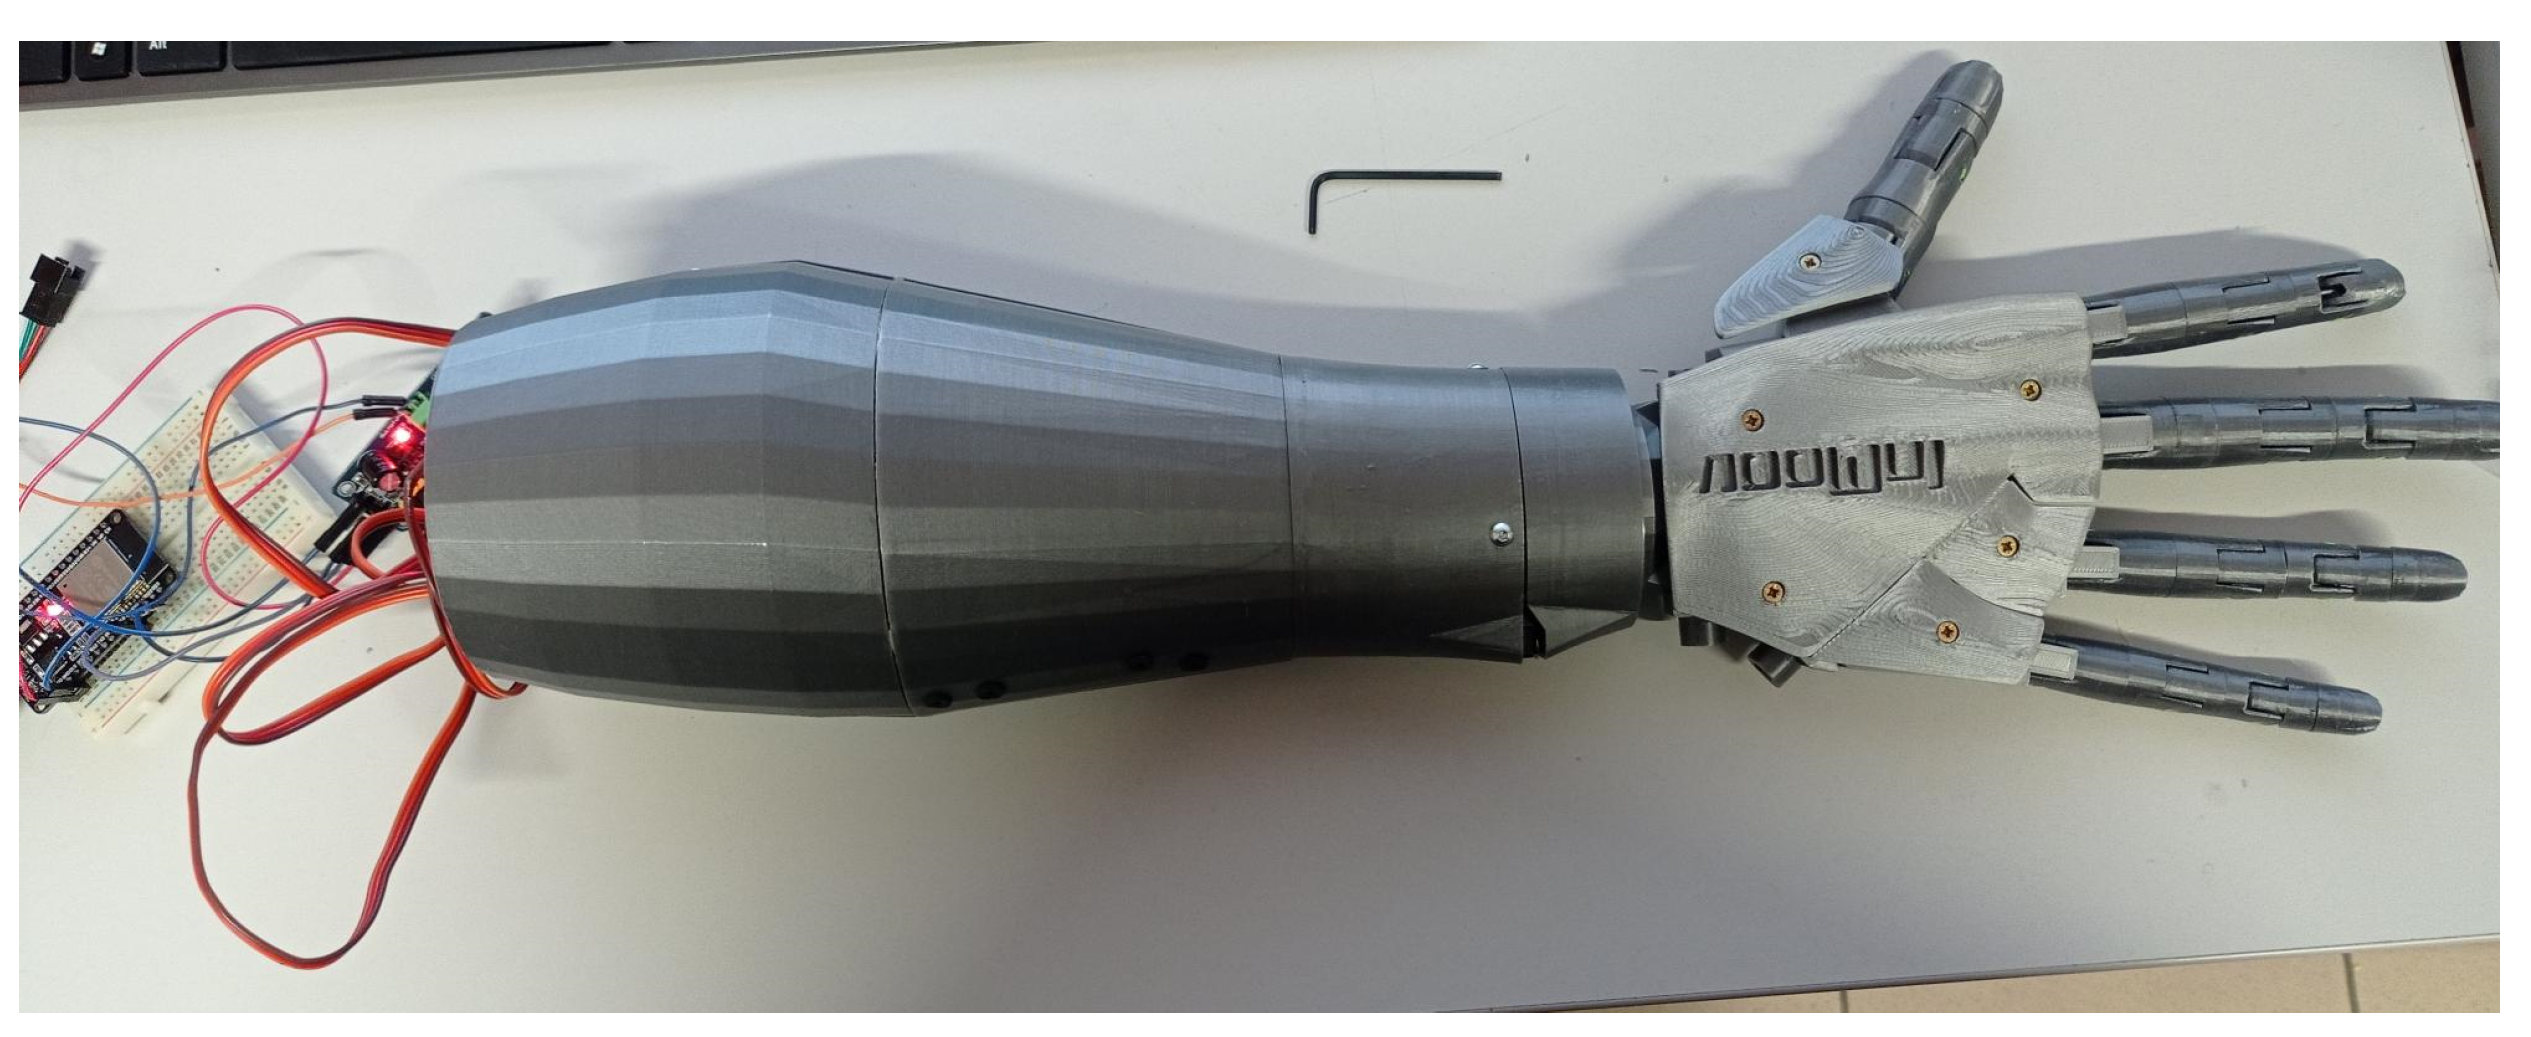
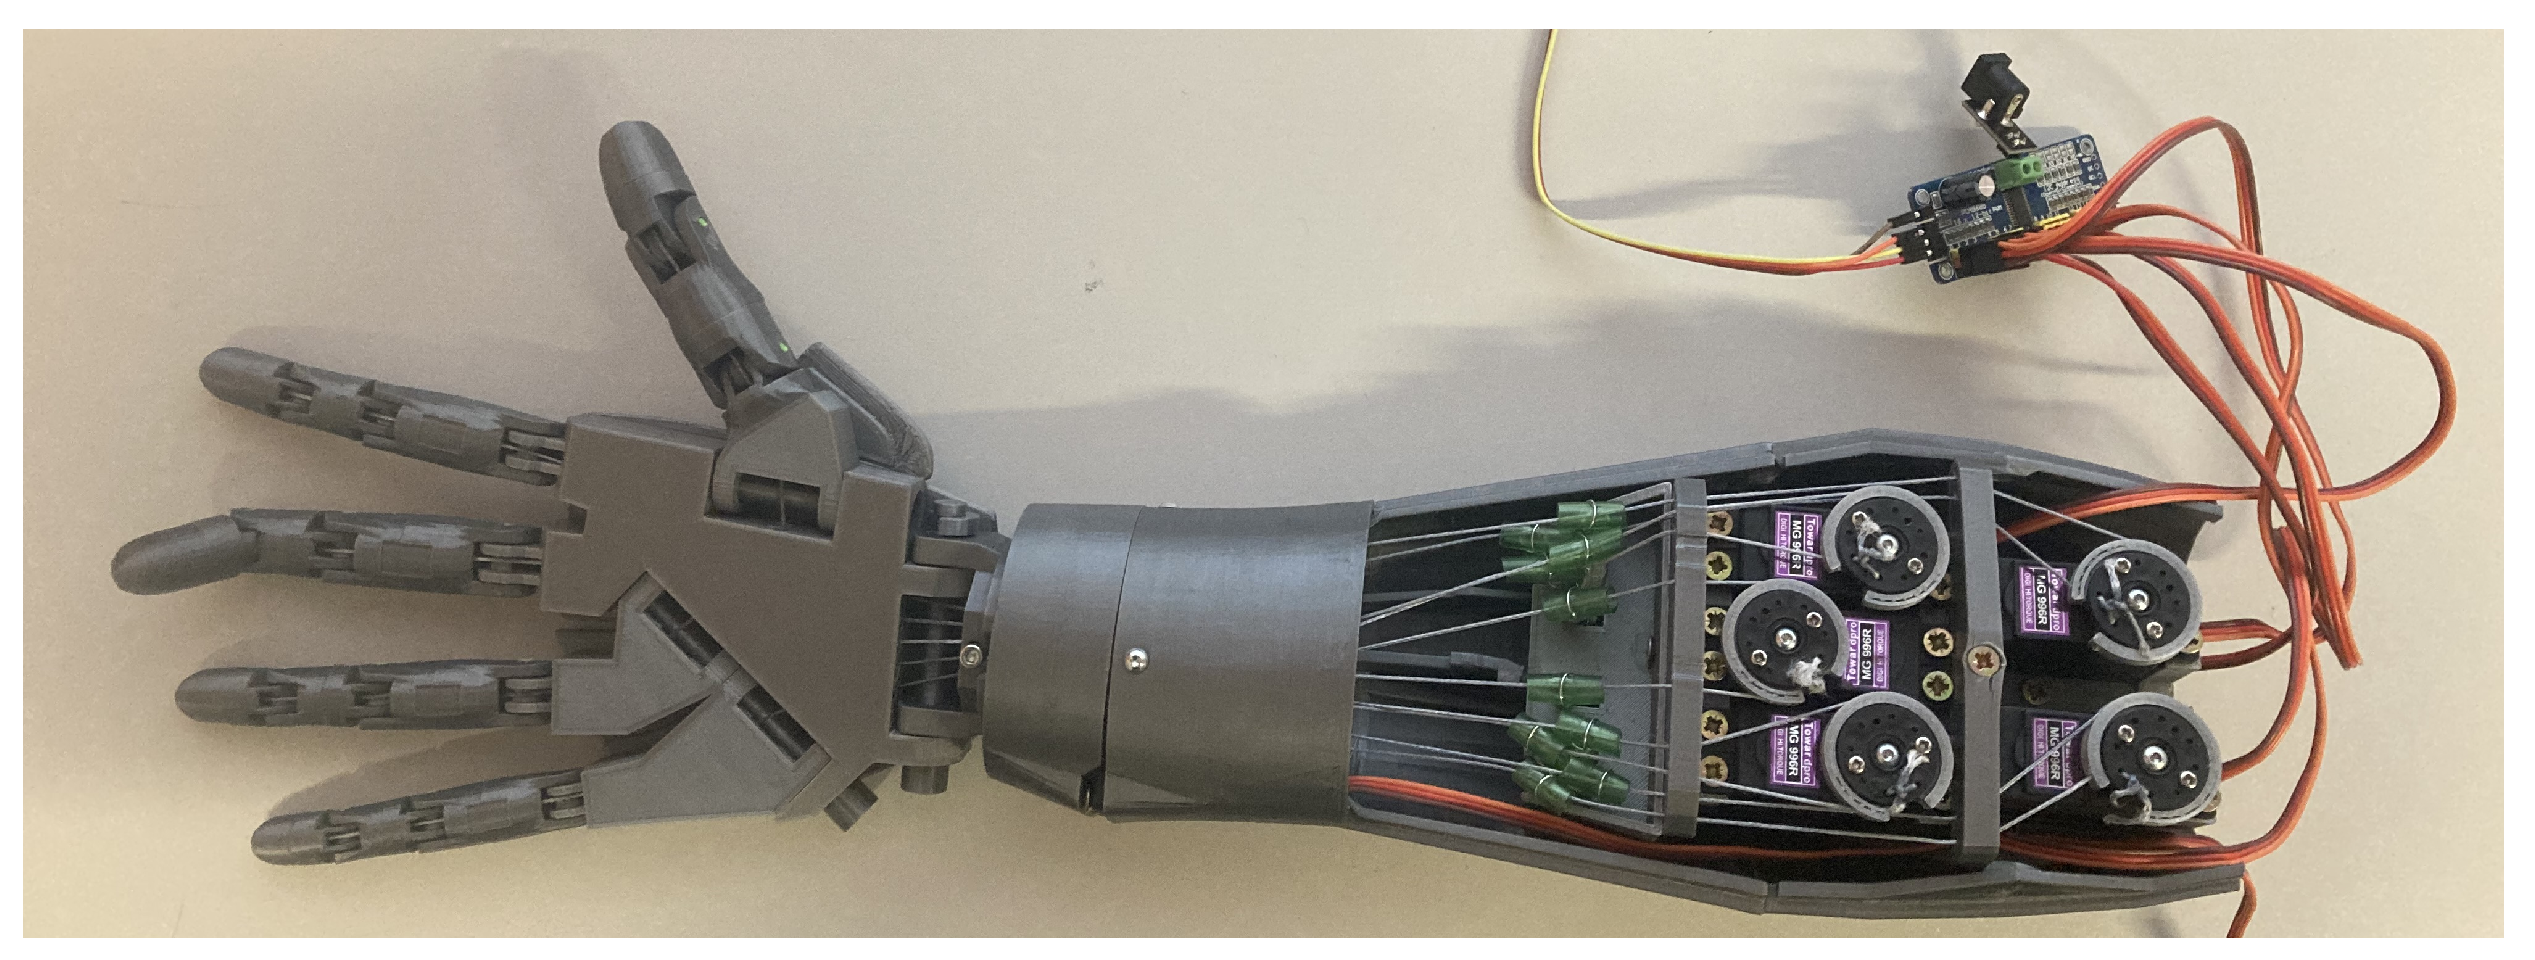
Model of Bionic Hand—Hardware
5. Results and Discussion
- Signal skewness in channel 3.
- Mean signal value in channel 1.
- Entropy of the first intrinsic mode function (IMF) from VMD decomposition in channel 8.
- Mean signal value in channel 4.
- Mean signal frequency in channel 6.
- Energy of the fifth IMF from EMD decomposition in channel 4.
- Correlation Dimension in channel 3.
- Total Harmonic Distortion (THD) in channel 6.
- Mean upper envelope of the signal in channel 5.
- Correlation Dimension in channel 2.
- Signal skewness in channel 3.
- Entropy of the first intrinsic mode function (IMF) from VMD decomposition in channel 8.
- Mean signal value in channel 1.
- Mean signal frequency in channel 6.
- Shape Factor in channel 1.
- Correlation Dimension in channel 3.
- Mean signal value in channel 4.
- Energy of the fifth IMF from EMD decomposition in channel 4.
- Energy of the first IMF from VMD decomposition in channel 6.
- Total Harmonic Distortion (THD) in channel 6.
6. Conclusions
Author Contributions
Funding
Institutional Review Board Statement
Informed Consent Statement
Data Availability Statement
Acknowledgments
Conflicts of Interest
References
- Hermens, H.J.; Freriks, B.; Disselhorst-Klug, C.; Rau, G. Development of recommendations for SEMG sensors and sensor placement procedures. J. Electromyogr. Kinesiol. 2000, 10, 361–374. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Merletti, R.; Farina, D. Surface Electromyography: Physiology, Engineering and Applications; John Wiley & Sons: Hoboken, NJ, USA, 2016. [Google Scholar]
- Farina, D.; Merletti, R. Principles of surface electromyography: Interpretation of the signal and applications. Exerc. Sport Sci. Rev. 2004, 32, 128–134. [Google Scholar] [CrossRef] [Scilit]
- Vigotsky, A.D.; Halperin, I.; Lehman, G.J.; Trajano, G.S.; Vieira, T.M.M. Surface electromyography: What limits its use in exercise and sport physiology? Front. Physiol. 2017, 8, 65. [Google Scholar] [CrossRef] [Scilit]
- Phinyomark, A.; Khushaba, R.N.; Scheme, E.J. Feature extraction and selection for myoelectric control based on wearable EMG sensors. Sensors 2018, 18, 1615. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Farina, D.; Enoka, R.M. The extraction of neural strategies from the surface EMG: 2004–2024. J. Appl. Physiol. 2025, 138, 1081–1093. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Atzori, M.; Gijsberts, A.; Castellini, C.; Caputo, B.; Mougiakakou, S.G.; Müller, H. Evaluation of the forearm EMG signal features for the control of a prosthetic hand. In Proceedings of the 2014 IEEE International Conference on Systems, Man, and Cybernetics (SMC), San Diego, CA, USA, 5–8 October 2014; pp. 2917–2921. [Google Scholar] [CrossRef] [Scilit]
- Oskoei, M.A.; Hu, H. Techniques of EMG signal analysis: Detection, processing, classification and applications. Biol. Proced. Online 2007, 8, 11–35. [Google Scholar] [CrossRef] [Scilit]
- Recommendations for Sensor Locations on Individual Muscles. Available online: https://www.nxp.com/design/microcontrollers-developer-resources/lpc-microcontroller-utilities/lpcxpresso-board-for-lpc1347:OM13045 (accessed on 8 June 2025).
- Pieprzycki, A.; Król, D. Concept of the EMG Controlled Bionic Hand. Sci. Technol. Innov. 2020, 8, 26–34. [Google Scholar] [CrossRef] [Scilit]
- Pieprzycki, A.; Krol, D.; Wawryka, P.; Łachut, K.; Hamera, M.; Srebro, B. Analysis of Surface EMG Signals to Control of a Bionic Hand Prototype. In Progress in Polish Artificial Intelligence Research 4; Wydawnictwo Politechniki Łódzkiej/Lodz University of Technology Press: Łódź, Poland, 2023. [Google Scholar]
- Wawryka, P. Analiza syganłóW Elektromiograficznych w Zastosowaniu Protetycznym. Bachelor’s Thesis, University of Applied Sciences in Tarnow, ul. Mickiewicza 8, Tarnow, Poland, 2022. [Google Scholar]
- EMG. Available online: https://github.com/informacja/EMG (accessed on 8 June 2025).
- Huang, N.E.; Shen, S.S.P. Hilbert-Huang Transform and Its Applications, 1st ed.; World Scientific: Singapore, 2005. [Google Scholar]
- Hilbert-Huang Transform. Available online: https://www.mathworks.com/matlabcentral/fileexchange/19681-hilbert-huang-transform (accessed on 8 June 2025).
- The MathWorks Inc. Statistics and Machine Learning Toolbox Documentation, Natick; The MathWorks Inc.: Natick, MA, USA, 2022; Available online: https://www.mathworks.com/help/stats/index.html (accessed on 8 June 2025).
- JMP®, Version 18.0.2.; SAS Institute Inc.: Cary, NC, USA, 2024.
- Huang, N.E.; Shen, S.S.P. Hilbert—Huang Transform and Its Applications, 2nd ed.; Interdisciplinary Mathematical Sciences; World Scientific: Singapore, 2014; Volume 16. [Google Scholar] [CrossRef] [Scilit]
- Dragomiretskiy, K.; Zosso, D. Variational Mode Decomposition. IEEE Trans. Signal Process. 2014, 62, 531–534. [Google Scholar] [CrossRef] [Scilit]
- Chun, S.; Kim, S.; Kim, J. Human Arm Workout Classification by Arm Sleeve Device Based on Machine Learning Algorithms. Sensors 2023, 23, 3106. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Tibshirani, R. Regression Shrinkage and Selection via the lasso. J. R. Stat. Soc. Ser. B (Methodol.) 1996, 58, 267–288. [Google Scholar] [CrossRef] [Scilit]
- Hoerl, A.E.; Kennard, R.W. Ridge Regression: Applications to Nonorthogonal Problems. Technometrics 1970, 12, 69–82. [Google Scholar] [CrossRef]
- Zou, H.; Hastie, T. Regularization and Variable Selection Via the Elastic Net. J. R. Stat. Soc. Ser. B Stat. Methodol. 2005, 67, 301–320. [Google Scholar] [CrossRef] [Scilit]
- Guyon, I.; Weston, J.; Barnhill, S.; Vapnik, V. Gene Selection for Cancer Classification using Support Vector Machines. Mach. Learn. 2002, 46, 389–422. [Google Scholar] [CrossRef] [Scilit]
- Hand Robot InMoovs. Available online: https://www.thingiverse.com/thing:17773 (accessed on 8 June 2025).
- Abdikenov, B.; Zholtayev, D.; Suleimenov, K.; Assan, N.; Ozhikenov, K.; Ozhikenova, A.; Nadirov, N.; Kapsalyamov, A. Emerging Frontiers in Robotic Upper-Limb Prostheses: Mechanisms, Materials, Tactile Sensors and Machine Learning-Based EMG Control: A Comprehensive Review. Sensors 2025, 25, 3892. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Yoo, H.-J.; Park, H.-j.; Lee, B. Boreom Myoelectric Signal Classification of Targeted Muscles Using Dictionary Learning. Sensors 2019, 19, 2370. [Google Scholar] [CrossRef] [Scilit] [PubMed]
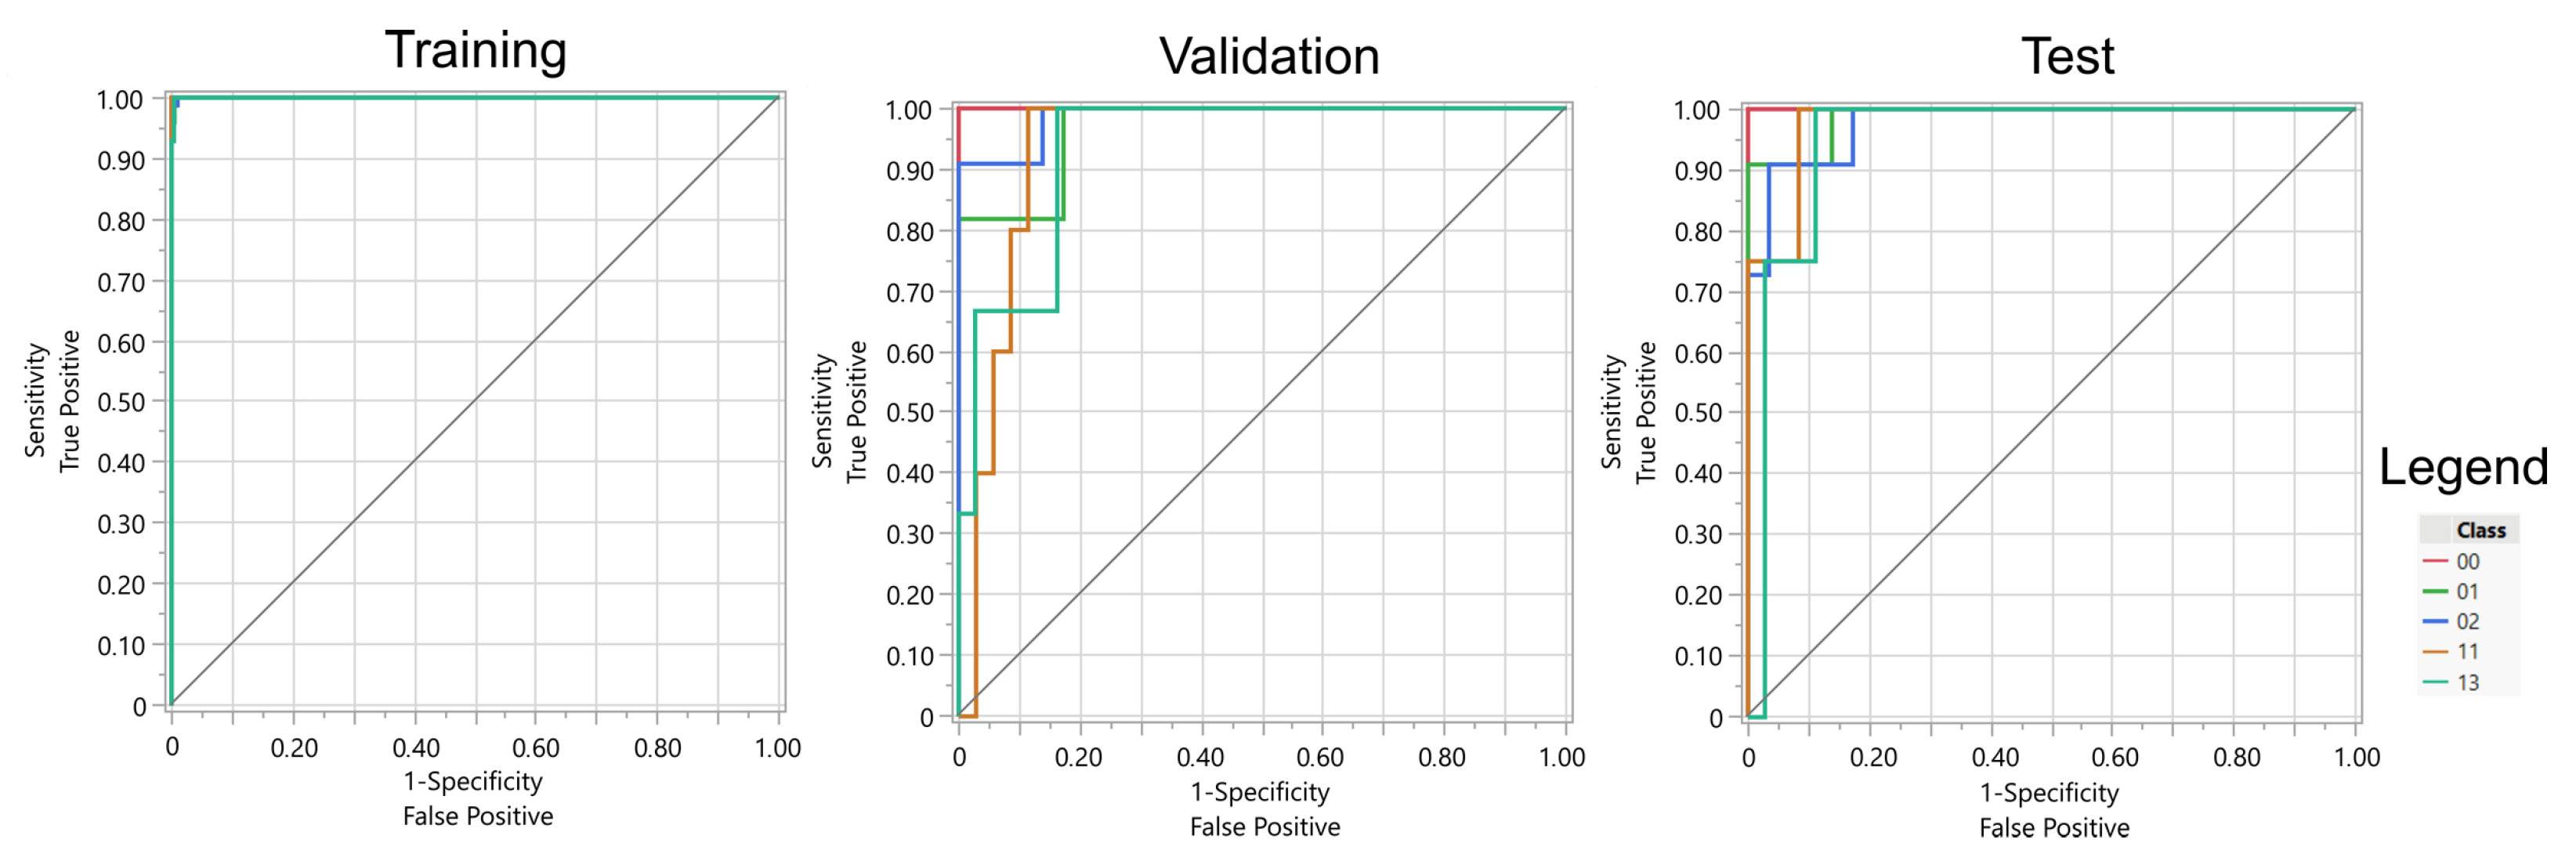
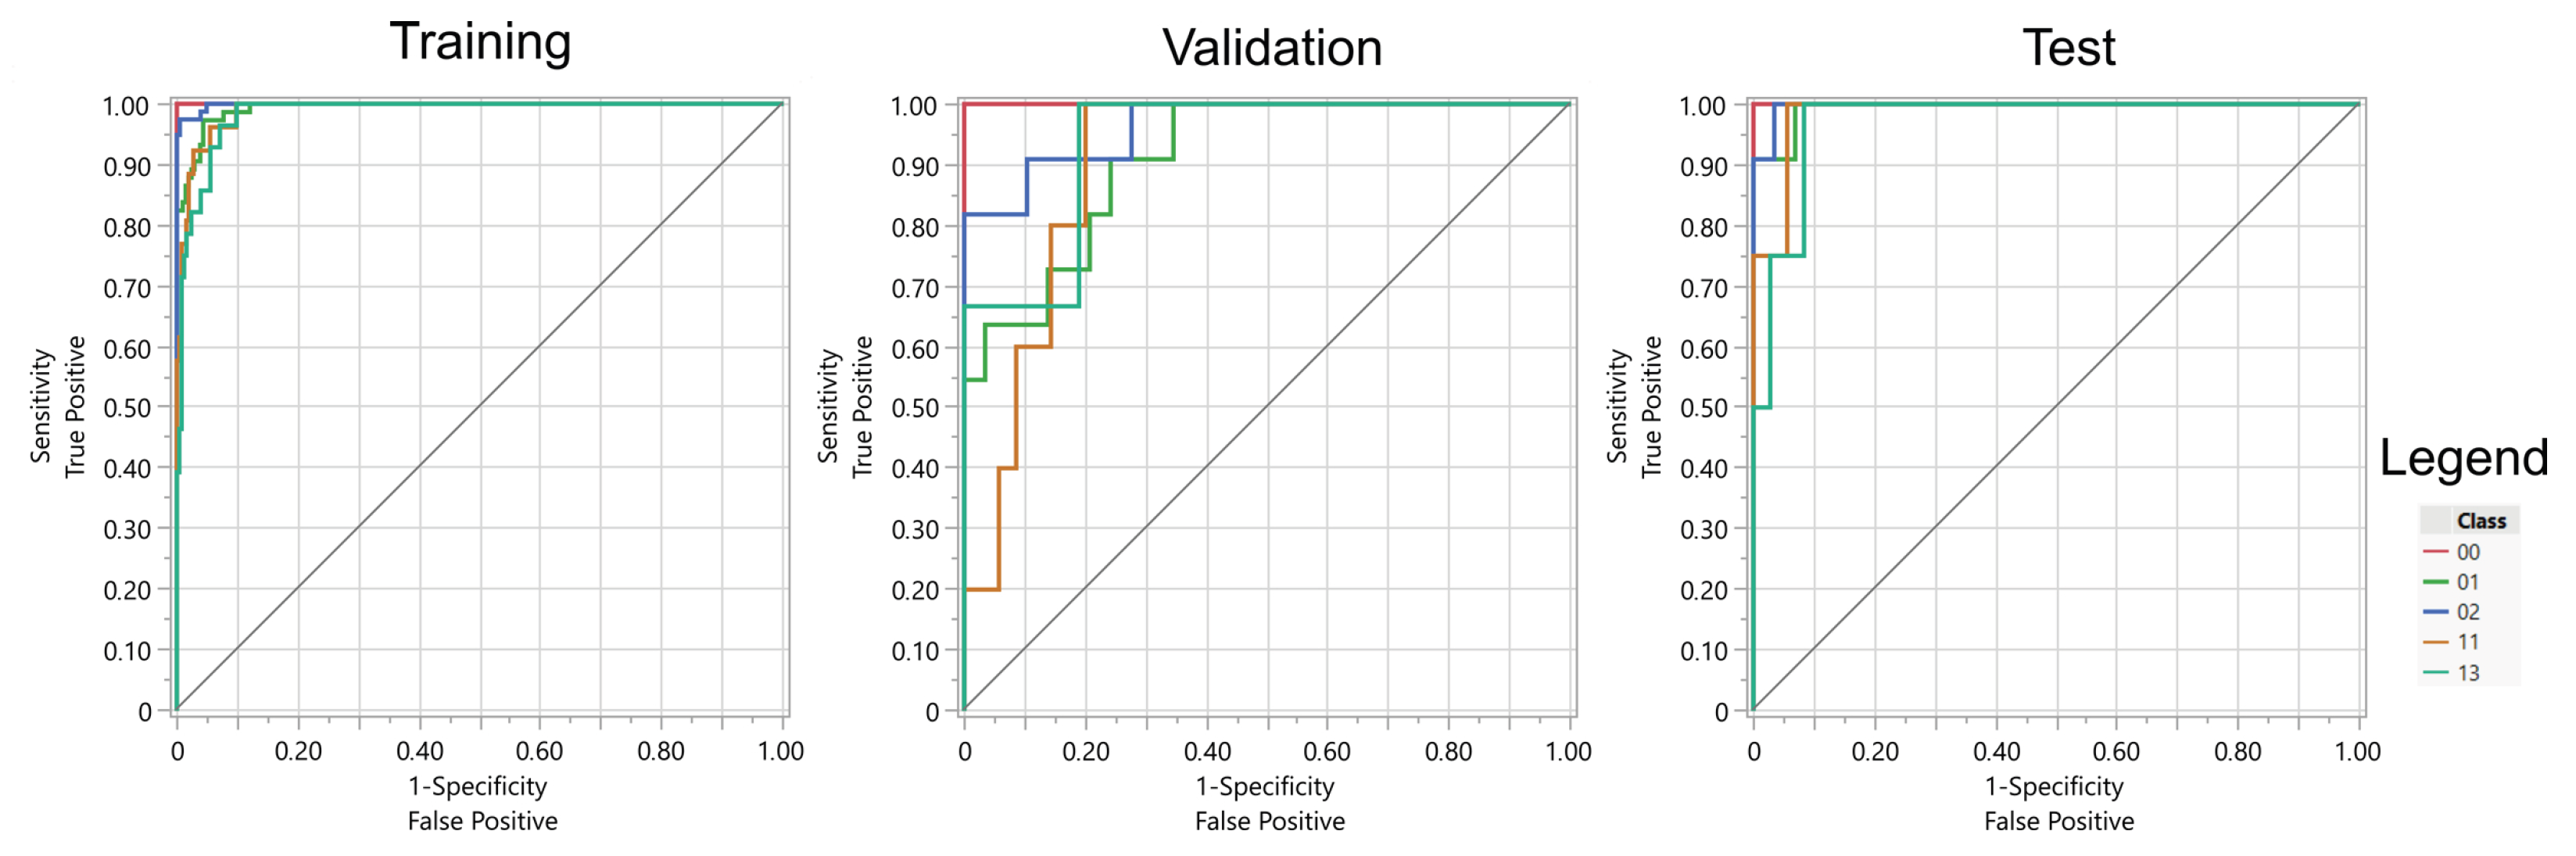

| Settings | Values |
|---|---|
| Number of sEMG channels (sensors) | 8 |
| Analyzed frequency range | 1–1024 Hz |
| Signal amplification | 1000 |
| Sampling frequency | 2048 Hz |
| Signal acquisition time | 5 s |
| Smooth signal | 5 samples |
| Unprocessed signal | 1. Mean, 2. RMS, 3. Shape Factor, 4. SNR, 5. THD, 6. SINAD, 7. Peak Value, 8. Crest Factor, 9. Clearance Factor, 10. Impulse Factor, 11. Kurtosis, 12. Skewness, 13. Approximate Entropy, 14. Energy, 15. Mean Frequency, 16. Mean Peaks, 17. Std Peaks, 18. Correlation Dimension |
| Envelopes | 1. Mean of upper envelope, 2. Std of upper envelope |
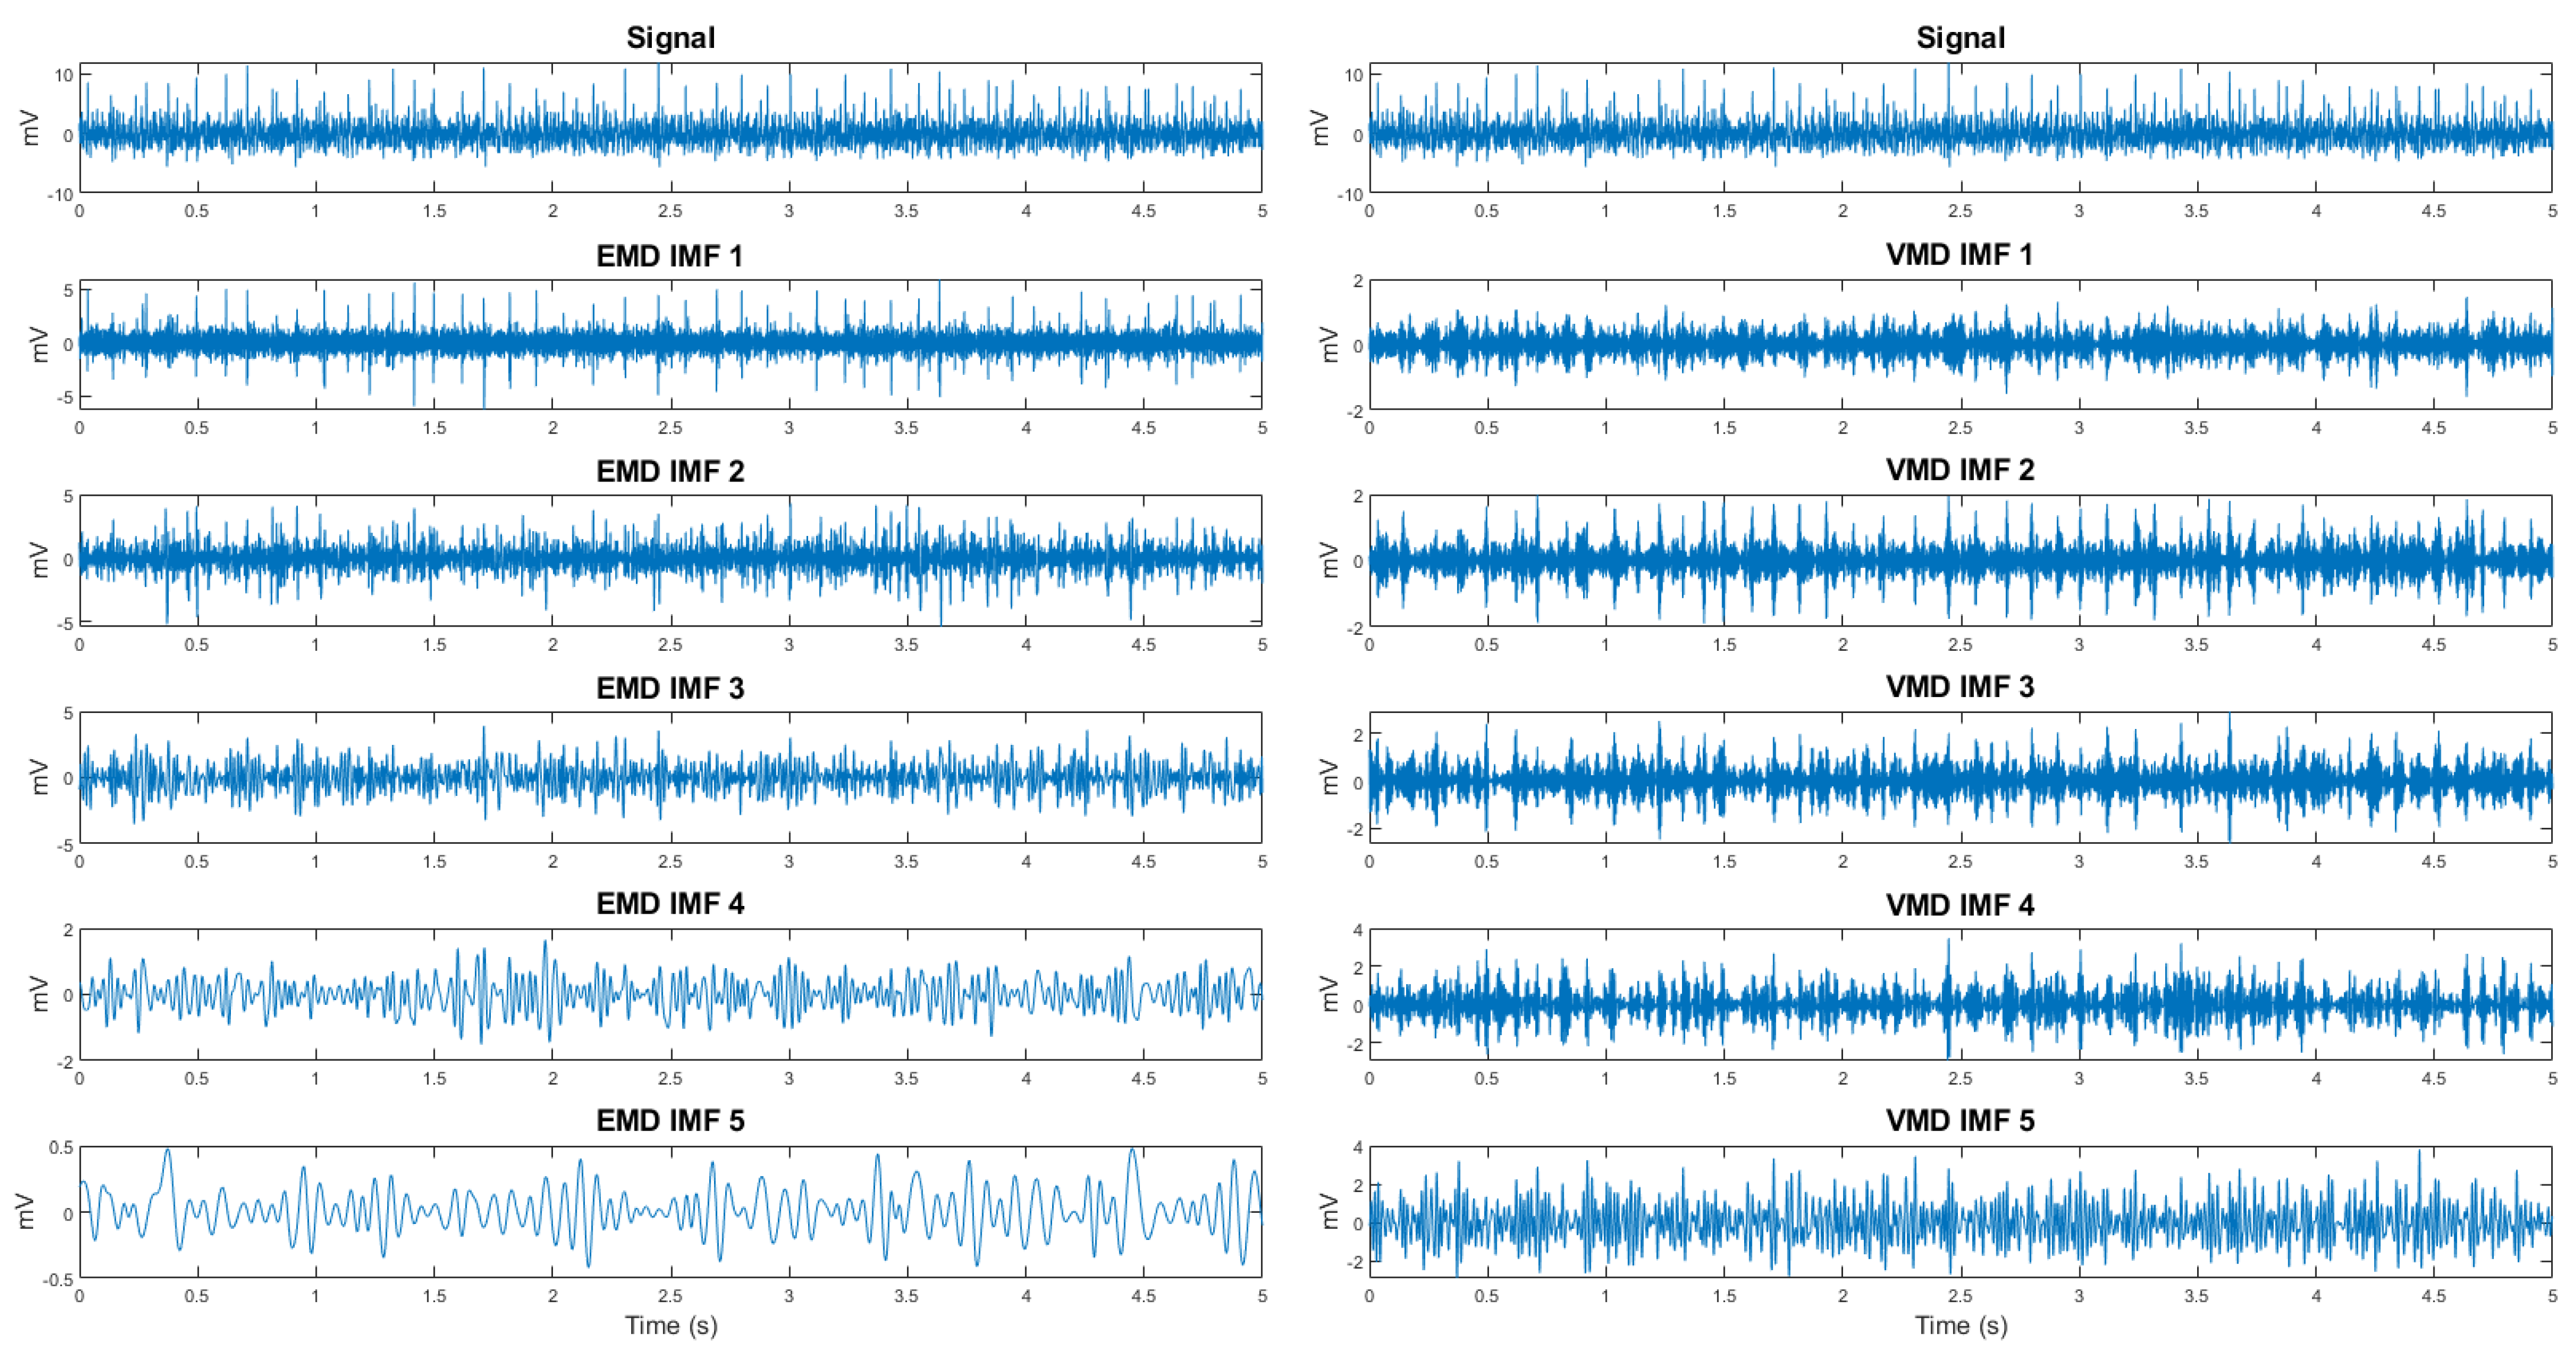
| Decomposition | 1. Entropy of imf, 2. Enegry of imf |
| Ridge Regression | Lasso Regression | Elastic Net Regression | |||||||
|---|---|---|---|---|---|---|---|---|---|
| Gesture | Train | Val | Test | Train | Val | Test | Train | Val | Test |
| 1 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 |
| 2 | 0.9930 | 0.9028 | 1.0000 | 0.9914 | 0.9060 | 0.9875 | 0.9930 | 0.9122 | 0.9937 |
| 3 | 0.9983 | 0.9561 | 0.9969 | 0.9990 | 0.9592 | 0.9937 | 0.9987 | 0.9655 | 0.9969 |
| 4 | 0.9946 | 0.9143 | 0.9653 | 0.9874 | 0.8857 | 0.9792 | 0.9896 | 0.9029 | 0.9861 |
| 5 | 0.9873 | 0.9369 | 0.9375 | 0.9821 | 0.9369 | 0.9722 | 0.9845 | 0.9369 | 0.9722 |
| RFE Regression | ANN (Linear Function) | ANN (Tanh Function) | |||||||
|---|---|---|---|---|---|---|---|---|---|
| Gesture | Train | Val | Test | Train | Val | Test | Train | Val | Test |
| 1 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 1.0000 | 0.9967 | 1.0000 | 1.0000 | 1.0000 |
| 2 | 1.0000 | 0.7962 | 0.9263 | 0.9360 | 0.9655 | 0.9185 | 0.9998 | 0.9687 | 0.9875 |
| 3 | 1.0000 | 0.7241 | 0.8777 | 0.9871 | 0.9655 | 0.9028 | 0.9999 | 0.9875 | 0.9781 |
| 4 | 1.0000 | 0.8443 | 0.7917 | 0.9593 | 0.9600 | 0.9097 | 1.0000 | 0.9371 | 0.9792 |
| 5 | 1.0000 | 0.9369 | 0.8819 | 0.9100 | 0.9459 | 0.9236 | 0.9997 | 0.9369 | 0.9514 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).
Share and Cite
Pieprzycki, A.; Król, D.; Srebro, B.; Skobel, M. Analysis of Surface EMG Signals to Control of a Bionic Hand Prototype with Its Implementation. Sensors 2025, 25, 5335. https://doi.org/10.3390/s25175335
Pieprzycki A, Król D, Srebro B, Skobel M. Analysis of Surface EMG Signals to Control of a Bionic Hand Prototype with Its Implementation. Sensors. 2025; 25(17):5335. https://doi.org/10.3390/s25175335
Chicago/Turabian StylePieprzycki, Adam, Daniel Król, Bartosz Srebro, and Marcin Skobel. 2025. "Analysis of Surface EMG Signals to Control of a Bionic Hand Prototype with Its Implementation" Sensors 25, no. 17: 5335. https://doi.org/10.3390/s25175335
APA StylePieprzycki, A., Król, D., Srebro, B., & Skobel, M. (2025). Analysis of Surface EMG Signals to Control of a Bionic Hand Prototype with Its Implementation. Sensors, 25(17), 5335. https://doi.org/10.3390/s25175335