1. Introduction
The reliability of spacecraft onboard control systems is one of the key factors determining the success of space missions and the duration of their operational lifetime [
1,
2]. During space operation, onboard equipment is exposed to a range of adverse environmental factors, including ionizing radiation, thermal fluctuations, vacuum conditions, micrometeoroid impacts, and electromagnetic disturbances [
1,
3,
4]. These factors may lead either to gradual degradation of components or to sudden failures of functional subsystems.
Modern spacecraft onboard control systems are complex multi-component structures comprising sensors, computing modules, actuators, and data transmission channels. The increase in functional complexity is accompanied by a growth in the number of inter-component connections, which leads to more intricate system architectures and an increased number of potential failure points. Under these conditions, system reliability is determined not only by the characteristics of individual components but also by the structure of their interactions (structural topology) [
3,
4].
Traditional reliability analysis methods, such as reliability block diagrams, fault tree analysis, and probabilistic models, are widely used to assess the impact of component failures on system performance [
3,
4]. However, these approaches have limitations when applied to systems with complex topology and multiple interdependencies, which necessitates the use of more formalized structural and topology-based analysis methods.
One promising direction is the application of graph theory and complex network methods, which allow a system to be represented as a directed graph. In such models, nodes correspond to functional elements of the system, while edges represent connections and the direction of control signal propagation. Studies [
5,
6] have shown that connectivity characteristics, node degree distribution, and shortest-path structure are important parameters in the analysis of complex network behavior.
The influence of topology on system fault tolerance is of particular importance in reliability analysis. It has been demonstrated in [
7] that the robustness of complex networks against random failures and targeted attacks strongly depends on the structure of inter-node connections. In satellite communication and spacecraft systems, ref. [
8] investigates strategies for controlling the topology of satellite cluster networks to ensure reliable data transmission paths.
The study [
9] proposes a method for reliability analysis of real-time complex systems based on complex network theory, enabling the consideration of node and link failures as well as the identification of critical structural elements. Recent studies have also investigated graph-based robustness indicators and network connectivity entropy approaches for assessing the structural reliability of complex electromechanical systems. For engineering systems, the importance of failure modeling, risk assessment, and identification of vulnerable components is also emphasized in [
10,
11].
Recent research has further extended graph-based reliability analysis methods to include fault propagation modeling, probabilistic dependency structures, and advanced network-based robustness measures, such as fault–function graphs, timed failure propagation graphs, factor graph representations, and Bayesian network approaches for reliability assessment of complex engineering systems [
12,
13,
14].
In particular, these studies demonstrate the increasing role of graph-theoretic and probabilistic network models in capturing failure propagation behavior and structural vulnerability in aerospace and safety-critical systems [
12,
13,
14,
15].
Thus, the review of existing studies indicates that, despite the development of reliability theory and complex network approaches, the application of graph models for comparative analysis of real spacecraft onboard control system architectures remains insufficiently explored. In particular, a more detailed investigation is required into the influence of functional connectivity topology on the availability of redundant paths and system fault tolerance.
The aim of this work is to analyze the structural reliability and robustness of onboard control systems based on their representation as directed functional graphs. A modified approach is proposed for the comparative analysis of spacecraft architectures in terms of structural fault tolerance. The novelty of the proposed approach lies in the integrated structural graph-based evaluation framework, which combines topology reduction in onboard control system schemes, directed connectivity analysis, identification of critical nodes, and evaluation of alternative control signal propagation paths for comparative assessment of spacecraft architectures. The study involves the construction of graph models, identification of critical nodes, and analysis of the influence of connection topology on the availability of alternative control signal transmission paths.
2. Research Methodology
At the first stage of the study, the spacecraft Express-MD1 (Khrunichev State Research and Production Space Center, Moscow, Russia) and Electro-L (Lavochkin Association, JSC, Khimki, Russia) were selected as the objects of analysis. For convenience of presentation and simplification of notation, the onboard control system of the Express-MD1 spacecraft is hereinafter referred to as onboard system 1 (BS 1), while the system of the Electro-L spacecraft is referred to as onboard system 2 (BS 2).
Based on the original functional diagrams of these systems, a simplification procedure was performed by identifying the key functional elements, including sensors, computing modules, control subsystems, actuators, as well as interface and communication units.
The resulting simplified diagrams reflect the structure of control signal transmission and the interactions between the main system components.
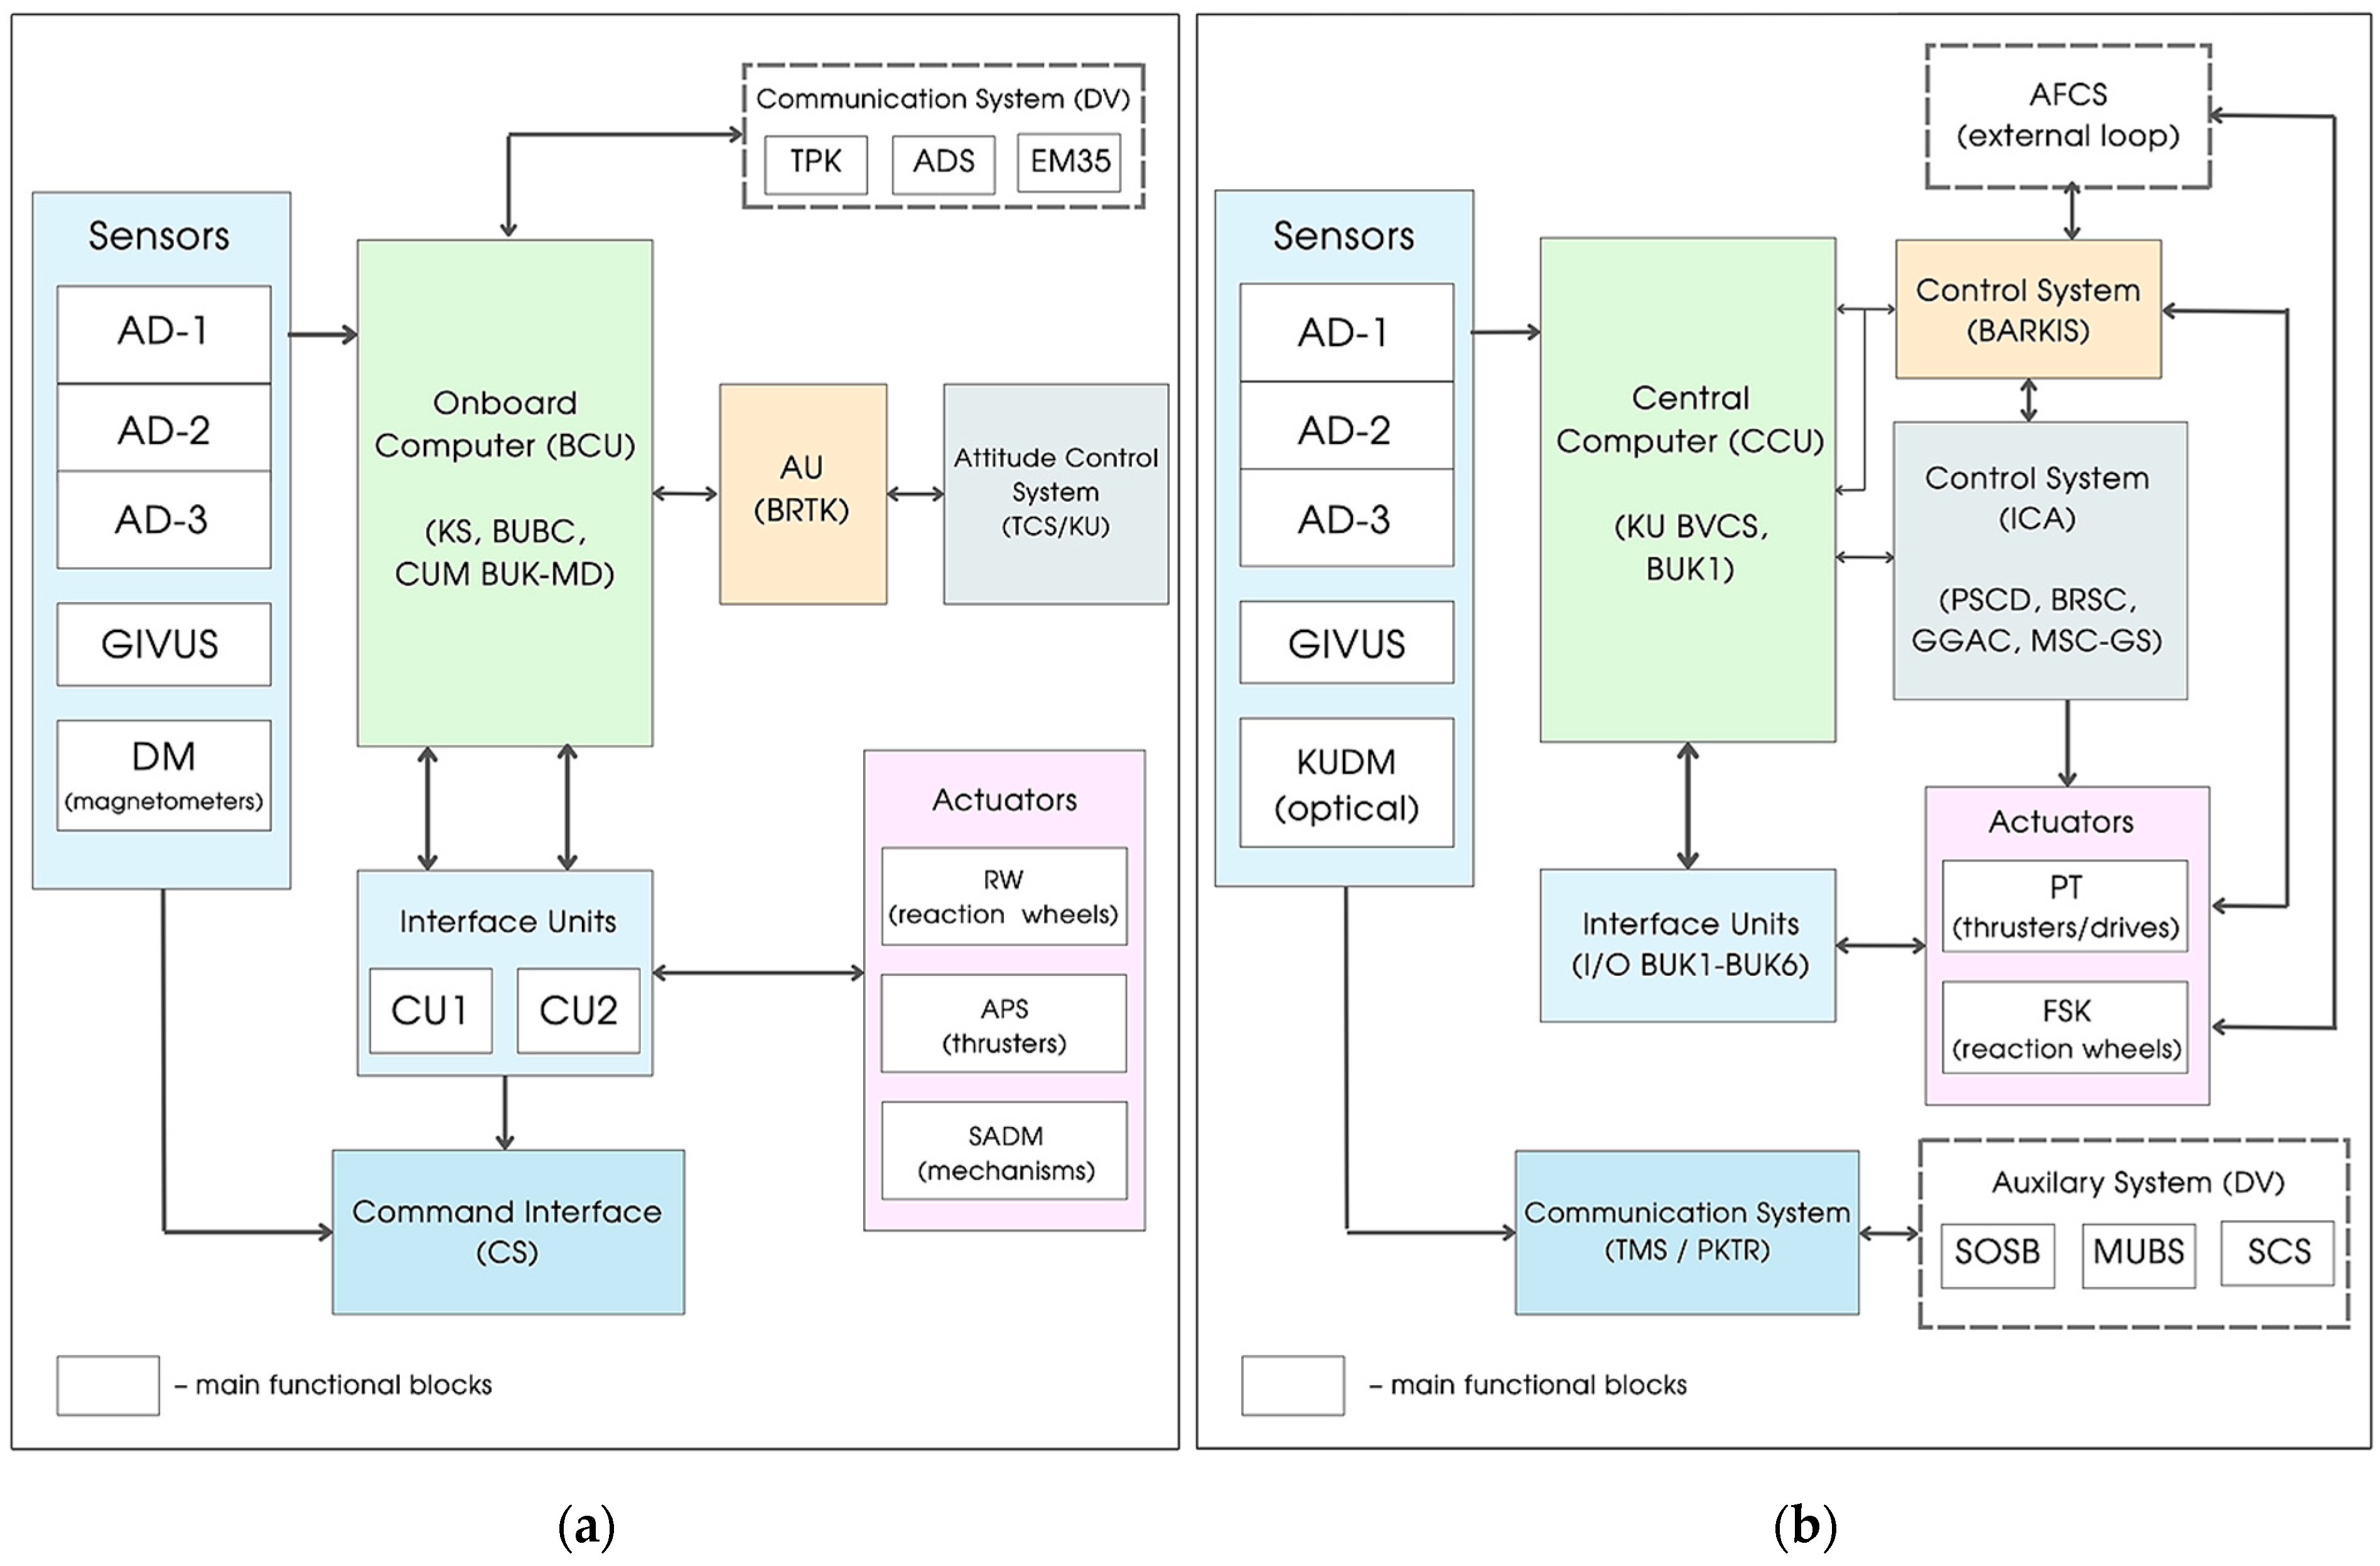
The simplified structural diagrams of the studied systems are presented in
Figure 1a,b.
2.1. Synthesis of Spacecraft Graph Models
Based on the simplified structural diagrams (
Figure 1), graph models were constructed. Each system is represented as a directed graph:
where
The construction of the graph model is carried out in the following sequence:
identification of the main functional blocks of the system under study;
assignment of each functional block to a corresponding graph vertex;
representation of inter-block connections as directed edges;
determination of each edge direction according to the direction of control signal flow.
At the first stage, the main functional blocks of the system are identified. This involves a structural analysis aimed at extracting key components responsible for signal processing, transmission, and transformation. Functional blocks are treated as logically distinct elements such as sensors, computing modules, interface units, control units, and actuators. The correctness of this stage directly affects the adequacy of the resulting graph model.
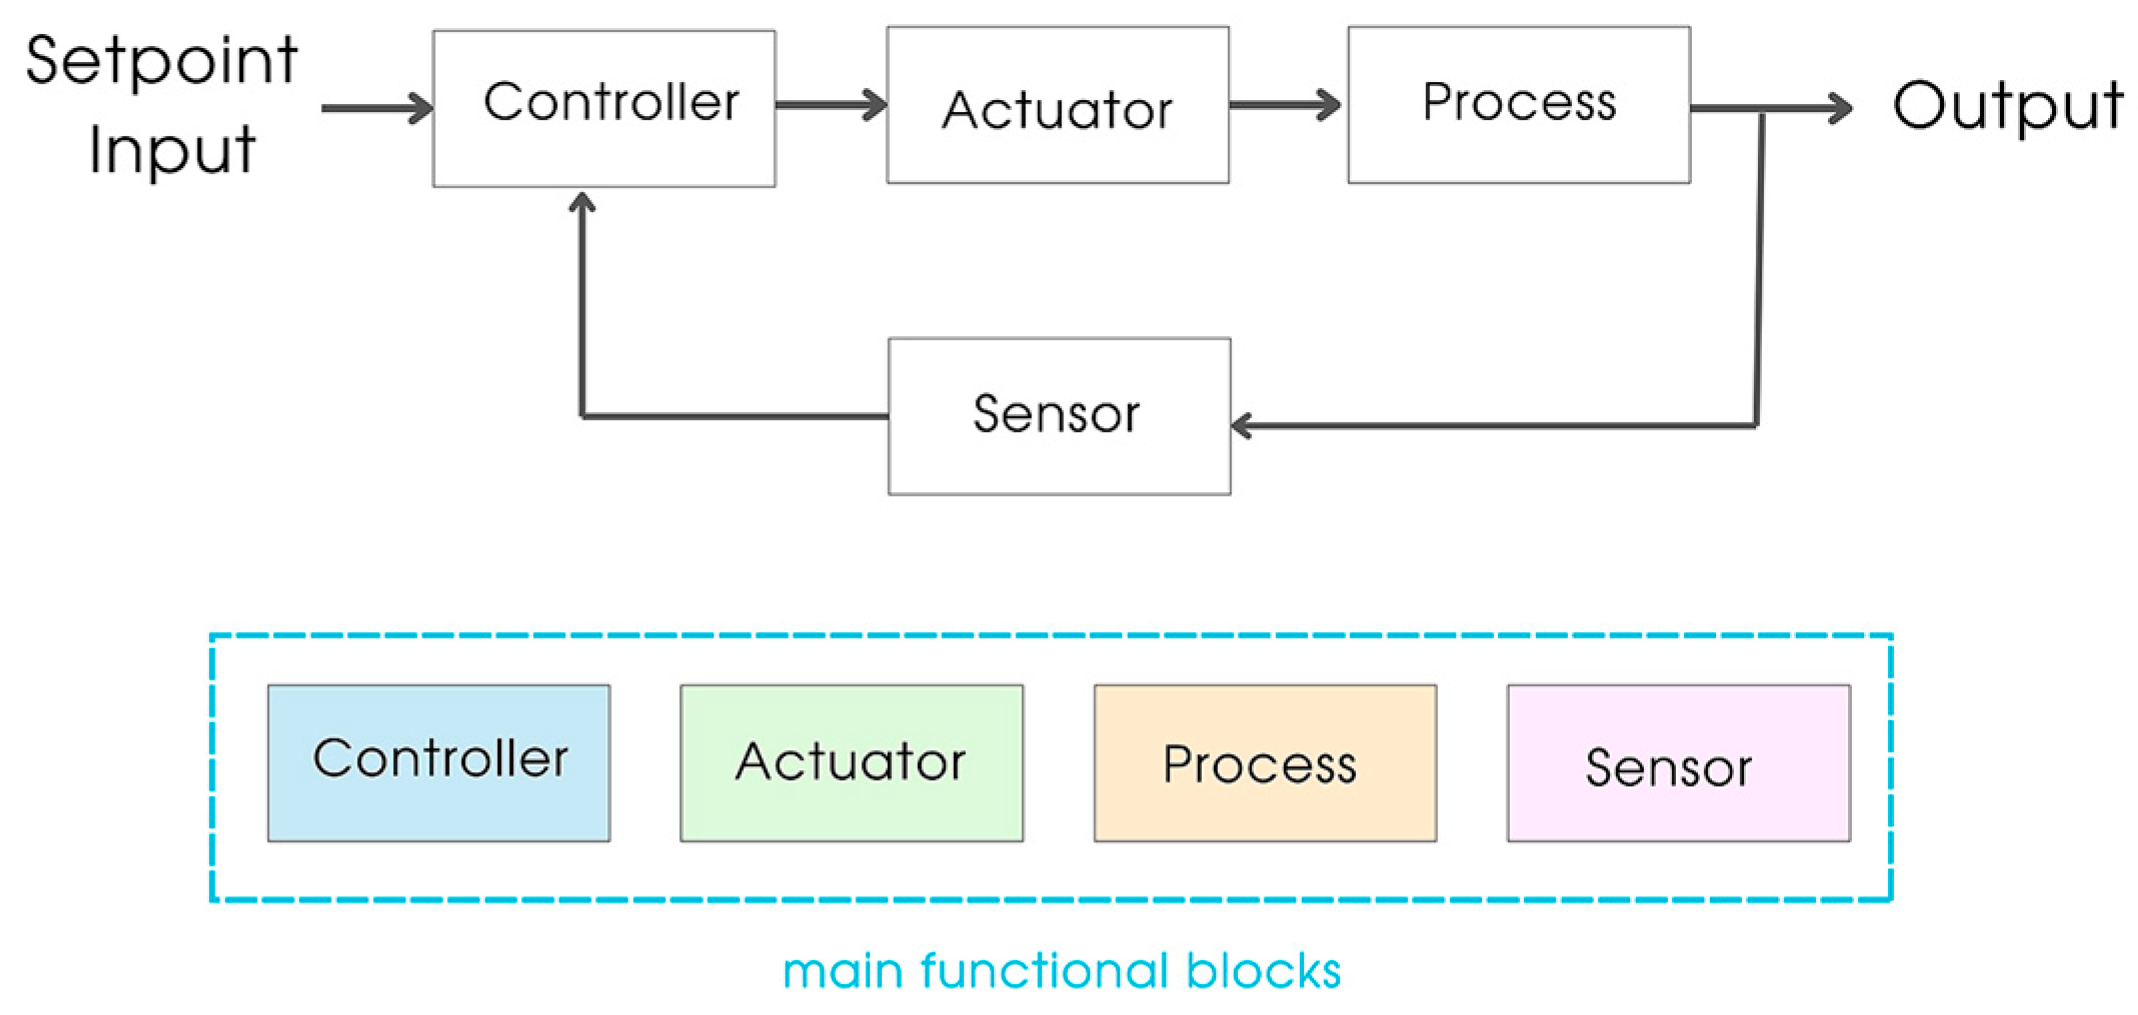
An illustration of the graph model construction procedure is shown in
Figure 2.
When formalizing the structural diagram, system components are interpreted as follows: sensor units are considered as sources of input information; computing systems as central data-processing nodes; interface modules as intermediate signal transmission elements; control units as elements generating control actions; and actuators as terminal nodes implementing control. This representation preserves the functional logic of the system within the graph model framework.
To automate the synthesis of graph models, a Python (v3.13.7)-based program was developed that enables the generation of directed graphs from a predefined system structure as well as their visualization. The use of a software implementation ensures reproducibility of results and the correctness of model construction.
As a result, graph models of onboard control systems corresponding to onboard system 1 (BS 1) and onboard system 2 (BS 2) were obtained.
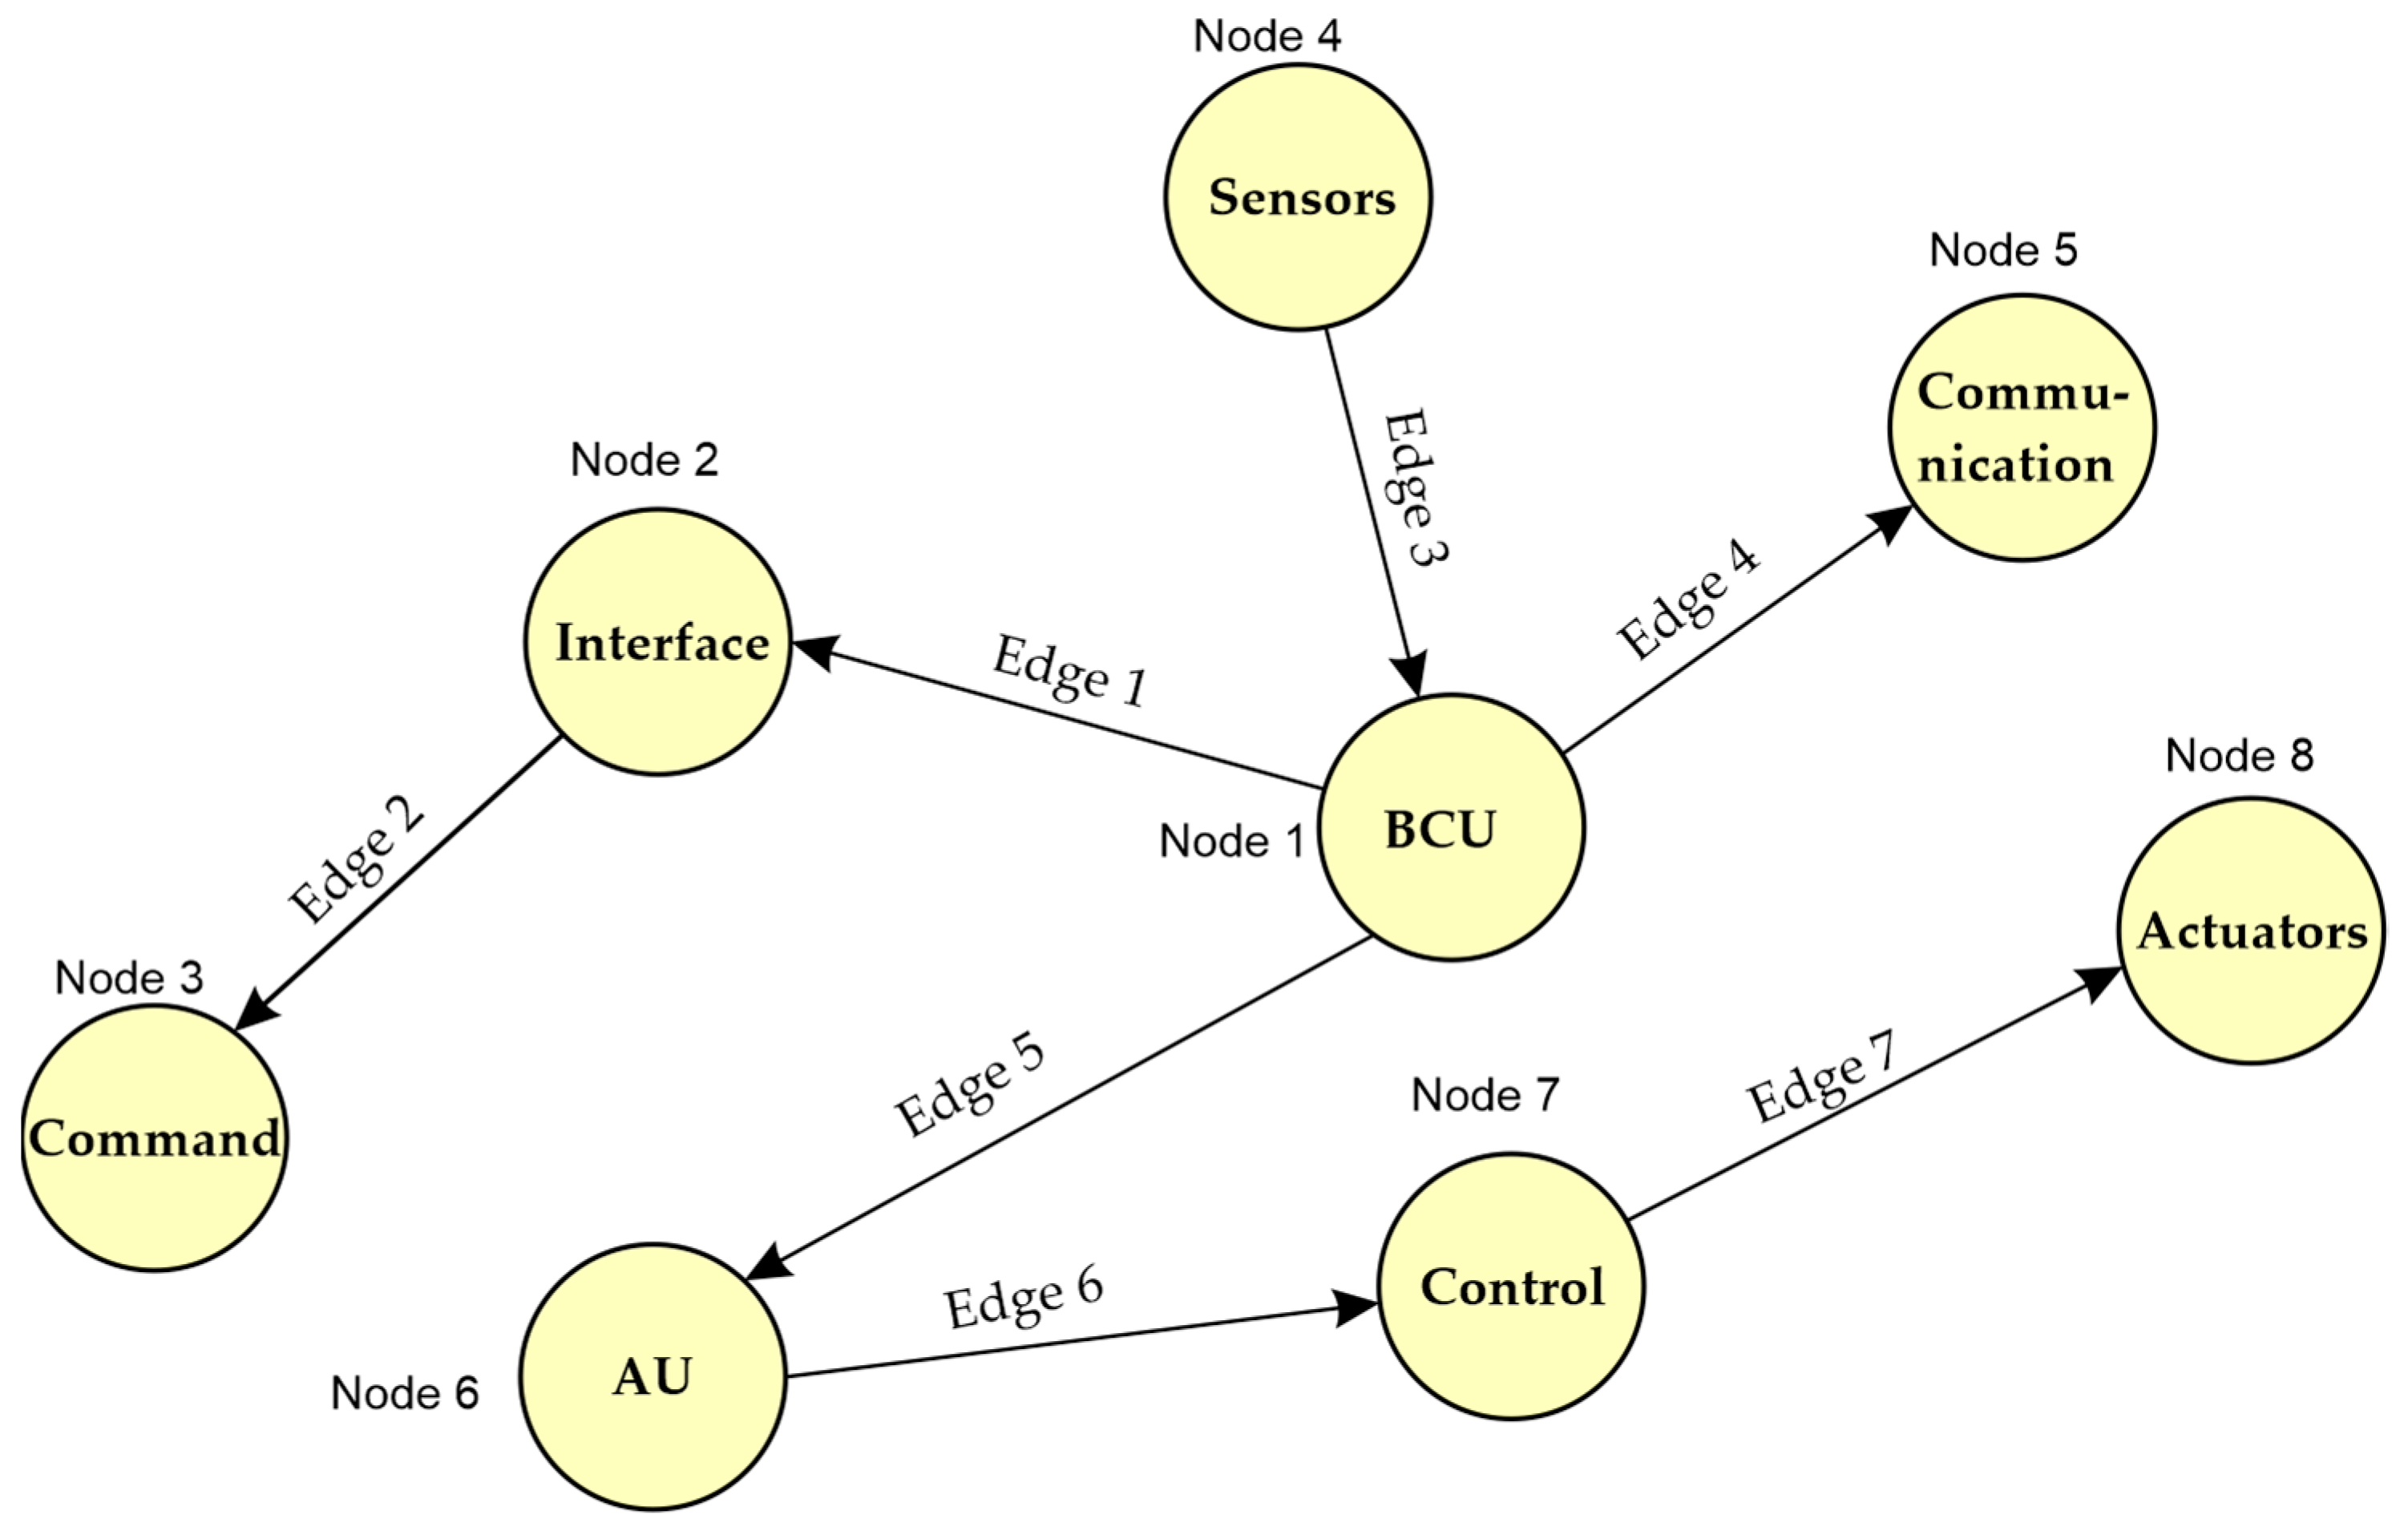
The graphs presented in
Figure 3 and
Figure 4 provide a graph-based representation of onboard control system architectures, where vertices correspond to functional subsystems and directed edges define information and control flows. This formalism captures both the structural composition and the interaction logic of the system components.
In BS 1 (
Figure 3), the onboard computing unit (BCU) serves as the central node through which most information and control flows are routed. The system includes sensors, an interface module, a control subsystem, actuators, a command unit, and an auxiliary unit, forming a predominantly sequential and centralized architecture with limited interconnections.
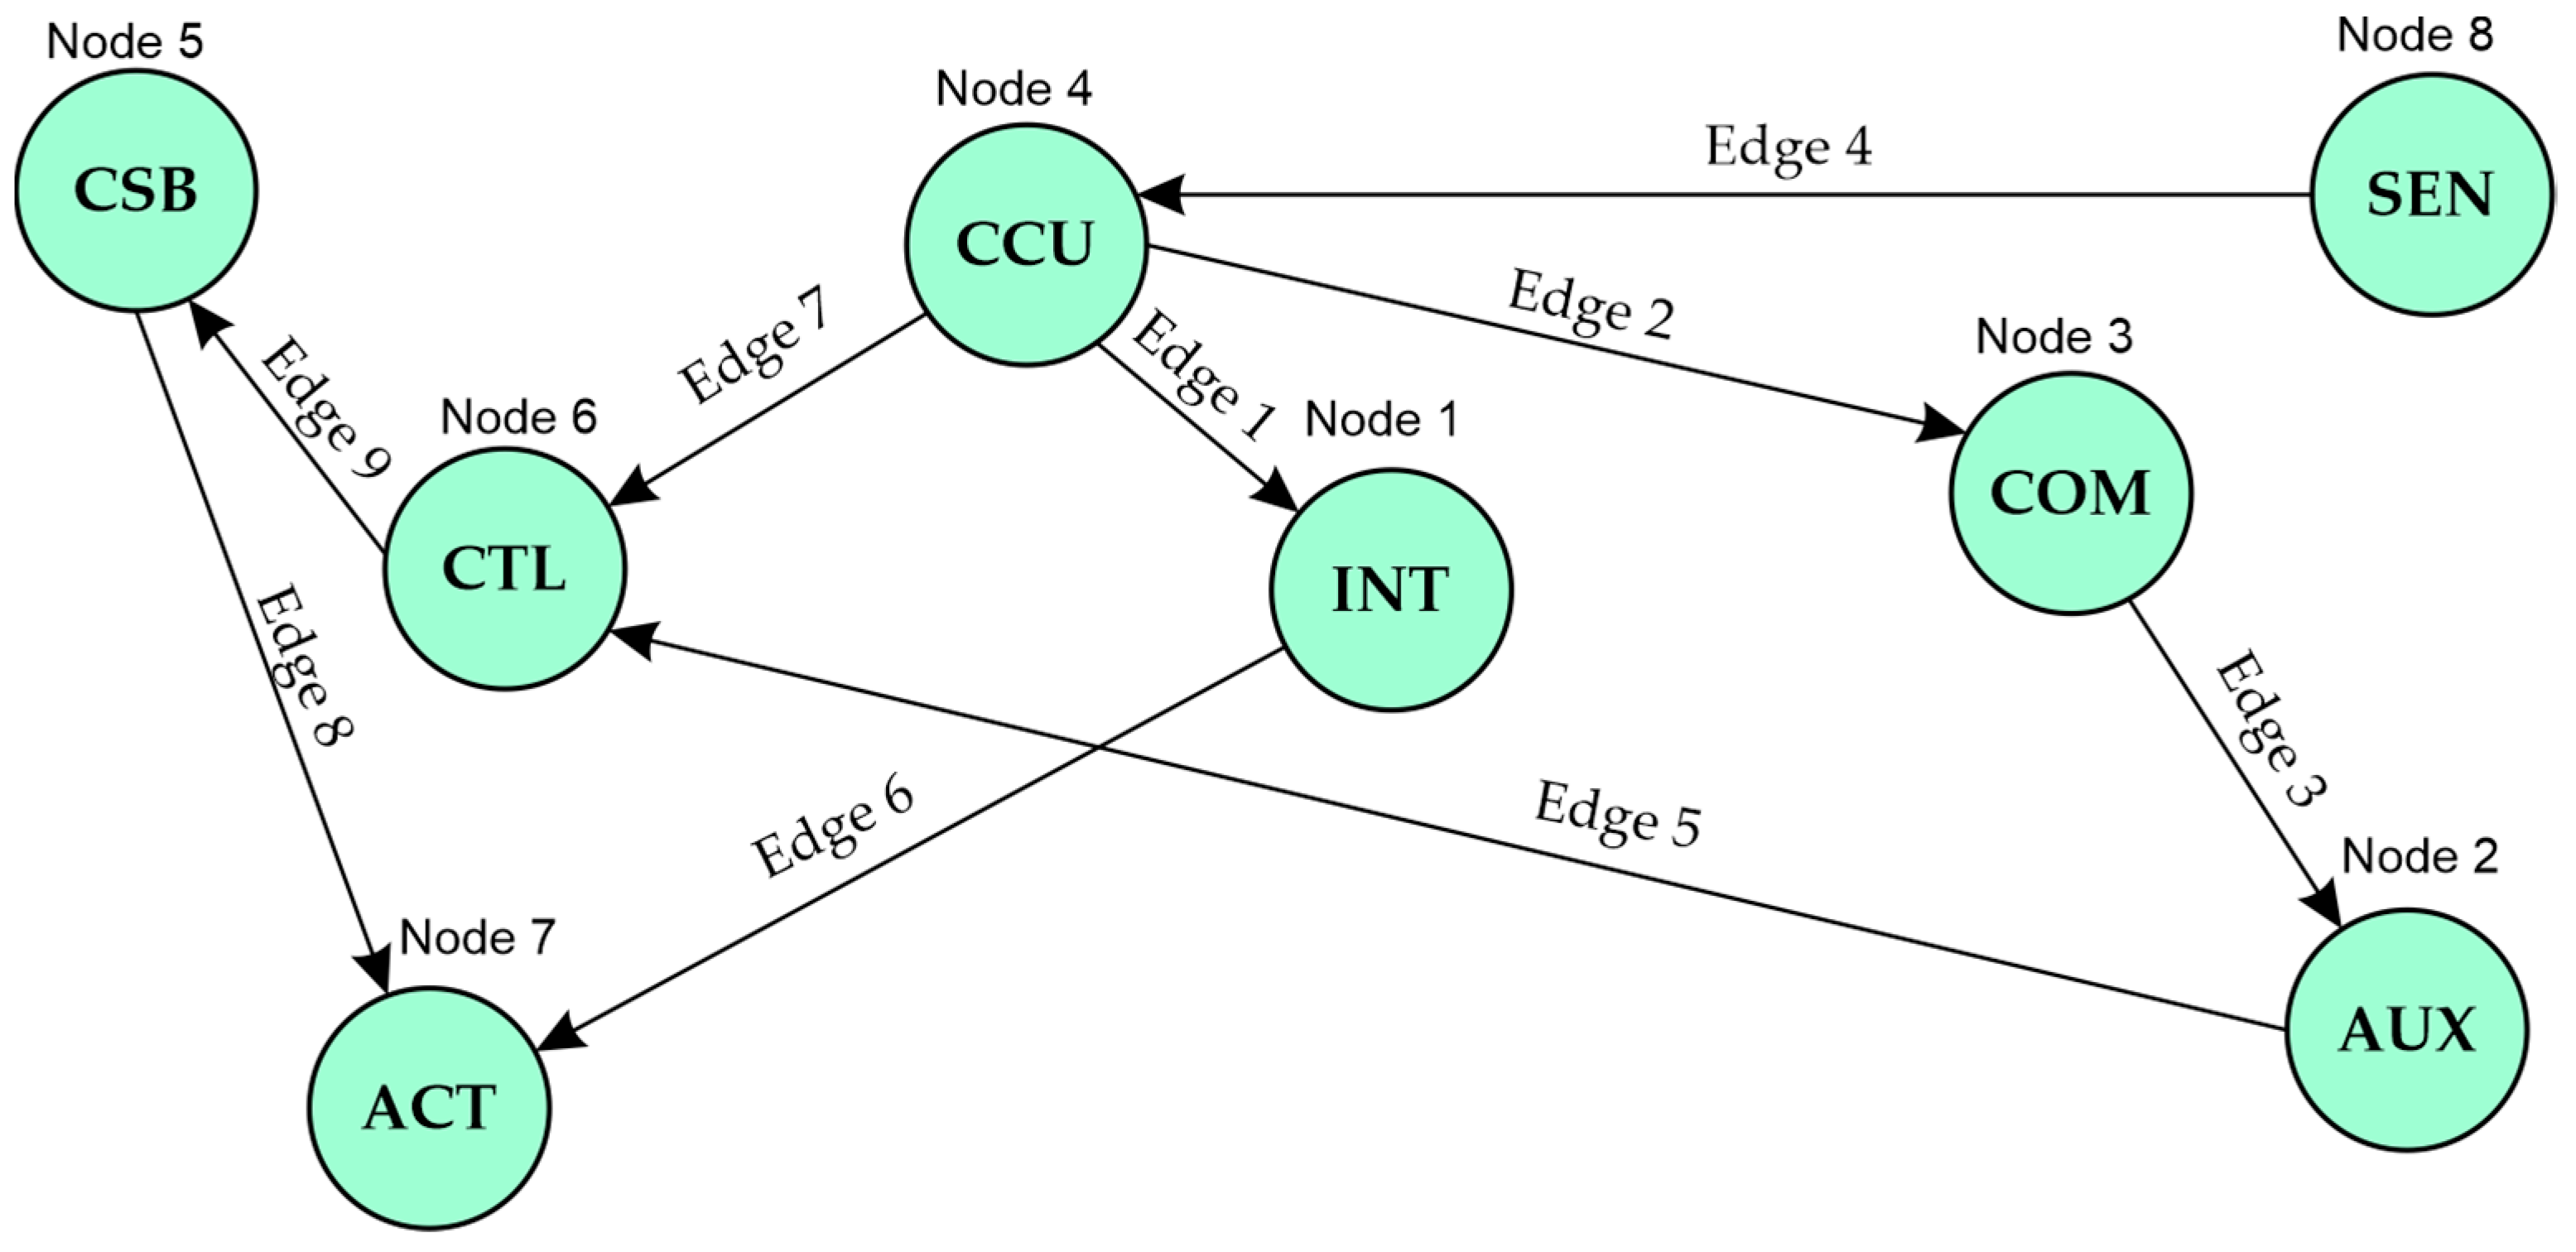
In contrast, BS 2 (
Figure 4) is characterized by a distributed structure, where the central computing unit (CCU) interacts with multiple subsystems, including interface, control, communication, sensor, actuator, and auxiliary modules. The presence of multiple interconnections and alternative signal paths increases system connectivity and reduces dependence on a single central node.
In BS 1 (
Figure 3), V
1 includes sensors, interface module, onboard computing unit (BCU), control subsystem, actuators, command unit, and auxiliary unit, each responsible for data acquisition, communication, processing, control generation, actuation, high-level commands, and support functions, respectively.
In BS 2 (
Figure 4), V
2 consists of CCU, INT, CTL, CSB, COM, ACT, SEN, and AUX, where control and processing are distributed across multiple interacting modules, increasing system decentralization.
A comparative analysis shows that BS 1 exhibits a centralized architecture with lower connectivity, while BS 2 demonstrates a distributed architecture with higher redundancy and structural robustness.
Thus, the synthesized graph models enable a formal representation of onboard control system structures and reveal key differences in their organization, which provides a basis for subsequent reliability analysis.
2.2. Comparative Reliability Analysis
Comparative reliability analysis of onboard spacecraft control systems is performed based on the topological characteristics of their graph models. The use of a graph-based approach makes it possible to formalize system structure and compare systems using a set of quantitative and qualitative indicators.
The main comparison parameters include:
the number of nodes , characterizing the number of functional elements in the system;
the number of edges , reflecting the number of inter-element connections;
graph density;
the presence of alternative paths between nodes;
the connectivity structure (centralized or distributed).
Graph density is defined as:
This metric characterizes the degree of system connectivity. A higher graph density indicates a larger number of interconnections between elements and, consequently, the potential existence of alternative routes for transmitting control signals.
Comparative analysis is carried out by contrasting these characteristics across the studied systems. Particular attention is given to identifying alternative signal transmission routes, as well as determining critical nodes whose failure may lead to system degradation or loss of functionality.
Thus, comparative reliability analysis makes it possible to assess the influence of graph topology on system robustness and serves as a basis for evaluating fault tolerance.
2.3. Reliability Assessment Criteria
The reliability of onboard spacecraft control systems is evaluated based on the analysis of topological properties of their corresponding graph models. The graph-based representation enables formalization of system structure and identification of factors affecting its resilience to failures.
The main reliability assessment criteria include:
System connectivity characterizes the ability to transmit control signals between all functional elements of the graph. High connectivity ensures system operability under partial disruption of links.
Presence of alternative paths reflects the existence of multiple routes for signal transmission between nodes. This criterion is a key indicator of fault tolerance, as redundant paths allow the system to continue operating in the event of node or edge failures.
Critical nodes are elements whose failure leads to significant degradation of system functionality. These are typically vertices with high connectivity or centrality, on which a substantial portion of the system depends.
Graph structure defines the distribution of functions among elements. Centralized structures are characterized by concentration of control within a limited number of nodes and, consequently, lower fault tolerance. Distributed structures provide a more balanced allocation of functions and higher reliability.
Thus, the presented criteria enable a comprehensive evaluation of onboard control system reliability based on structural organization and are used for subsequent comparative analysis.
The comparison of onboard spacecraft control systems BS 1 and BS 2 is performed based on the constructed graph models and calculated topological characteristics. The analysis is carried out for both systems in order to identify structural organization features and assess the influence of topology on system reliability.
The main focus is placed on:
the presence of redundant connections and alternative signal transmission paths;
distribution of functions among system elements;
degree of control centralization;
identification of critical nodes and their impact on system performance.
This approach makes it possible to reveal structural differences between the systems, determine their fault tolerance levels, and establish the influence of architecture on the reliability of onboard control complexes.
3. Results and Discussion
Graph models of onboard spacecraft control systems BS 1 and BS 2 were synthesized based on simplified structural diagrams (
Section 2.1) and represented as directed graphs, where vertices correspond to functional subsystems and edges represent the directions of information and control signal flow.
Based on the obtained models, an analysis of topological characteristics (
Section 2.2) and structural reliability and fault tolerance criteria (
Section 2.3) was performed.
The graph model (
Figure 3) is characterized by a centralized architecture. The onboard computing complex (BCU) is the key node with a high degree of connectivity through which the main information and control flows pass.
The typical signal transmission chain is:
The presence of an intermediate AU block increases the length of the control loop and introduces an additional sequential processing stage. From a topological perspective, this leads to:
increased path lengths (higher graph diameter);
concentration of connections in a limited number of nodes (BCU, AU) resulting in high node centrality and node criticality;
absence of alternative signal transmission routes (lack of redundancy in control paths).
As a result, failure of a central node or key edge may lead to fragmentation of a significant part of the graph, indicating reduced system fault tolerance and low structural robustness of the architecture.
The graph model (
Figure 4) demonstrates a distributed architecture with a more developed connectivity structure. The central computing unit (CCU) interacts with multiple subsystems, including interface (INT), control (CTL, CSB), communication (COM), and auxiliary (AUX) modules.
Signal transmission occurs along multiple routes, for example:
The presence of parallel paths and additional connections (including feedback links, e.g., AUX → CTL) increases graph connectivity. This provides:
alternative routes for control signal transmission;
reduced dependence on individual nodes (lower node criticality and higher distribution of centrality);
more balanced distribution of system load across components.
Such a topology corresponds to higher resilience against failures of individual components and connections, indicating improved structural robustness and fault tolerance.
Comparison of the graph models reveals significant differences in topology and reliability (
Table 1).
The comparison shows that, with an equal number of nodes, system BS 2 has a greater number of edges and, consequently, a higher graph density. This indicates the presence of additional connections and alternative signal transmission paths.
System BS 1 is characterized by dependence on key nodes (BCU, AU), which increases the risk of system failure in the event of their malfunction. In contrast, in the BS 2 model, the load is distributed more evenly, and the presence of redundant connections reduces the impact of failures of individual elements, leading to higher system-level structural robustness.
The analysis has shown that the topology of the onboard control system significantly affects its structural reliability and fault tolerance. The centralized structure of BS 1 is characterized by the presence of critical nodes (high node criticality) and a limited number of alternative paths, which reduces fault tolerance and overall structural robustness.
System BS 2 exhibits a distributed architecture with higher connectivity and the presence of redundant signal transmission routes, which ensures a higher level of fault tolerance and improved structural robustness.
Therefore, the onboard control system of spacecraft BS 2 demonstrates higher structural reliability and robustness compared to system BS 1.
The obtained results demonstrate that graph-based structural analysis can be effectively applied during the early stages of spacecraft onboard control system design. The proposed approach makes it possible to identify critical nodes, evaluate the availability of alternative control paths, and estimate the structural resilience of the system before detailed implementation. Such an analysis may support engineering decisions related to architecture optimization, redundancy allocation, and improvement of spacecraft fault tolerance.
At the same time, the proposed approach is primarily focused on the analysis of structural and topological properties of onboard control systems and does not include probabilistic failure modeling or stochastic reliability estimation. Therefore, the obtained results characterize the structural robustness of the considered architectures rather than the probability of system failure under real operational conditions. The integration of probabilistic reliability models and dynamic failure analysis may be considered as a direction for future research.
4. Conclusions
This study presents a comparative reliability analysis of onboard control systems of two spacecraft, BS 1 and BS 2, based on their representation as directed graph models.
At the initial stage, the original structural diagrams were simplified by identifying key functional elements and the connections between them. Based on these representations, graph models were constructed to reflect the structure of control signal transmission. The conducted analysis made it possible to evaluate topological characteristics of the systems, including connectivity, the presence of alternative paths, and the distribution of functional dependencies among elements.
It was established that the onboard control system of spacecraft BS 1 is characterized by a predominantly centralized architecture with critical nodes upon which a significant portion of the system depends. The presence of an intermediate control unit increases the length of functional paths and introduces additional potential points of failure.
In contrast, system BS 2 features a more distributed structure, characterized by higher connectivity and the presence of alternative control signal transmission paths. This ensures a higher level of redundancy and resilience to failures of individual elements and communication links.
The comparative analysis demonstrated that, with a comparable number of elements, differences in graph topology significantly affect system reliability. The higher connectivity and distributed structure of BS 2 provide improved fault tolerance compared to BS 1.
Thus, the obtained results confirm the effectiveness of applying graph models for the reliability analysis of onboard spacecraft control systems. This approach enables the identification of critical structural elements, assessment of the impact of topology on system resilience, and can be applied in the design of advanced onboard control systems for aerospace vehicles.
Additionally, it was established that the topology of an onboard control system is one of the key factors determining its reliability and fault tolerance. Increasing graph connectivity and the availability of alternative control signal transmission paths contribute to enhanced fault tolerance and reduced impact of single-point failures.
A promising direction for further research is the development of quantitative reliability assessment methods based on probabilistic failure models, as well as optimization of onboard control system structures using graph-based criteria while accounting for fault tolerance requirements.