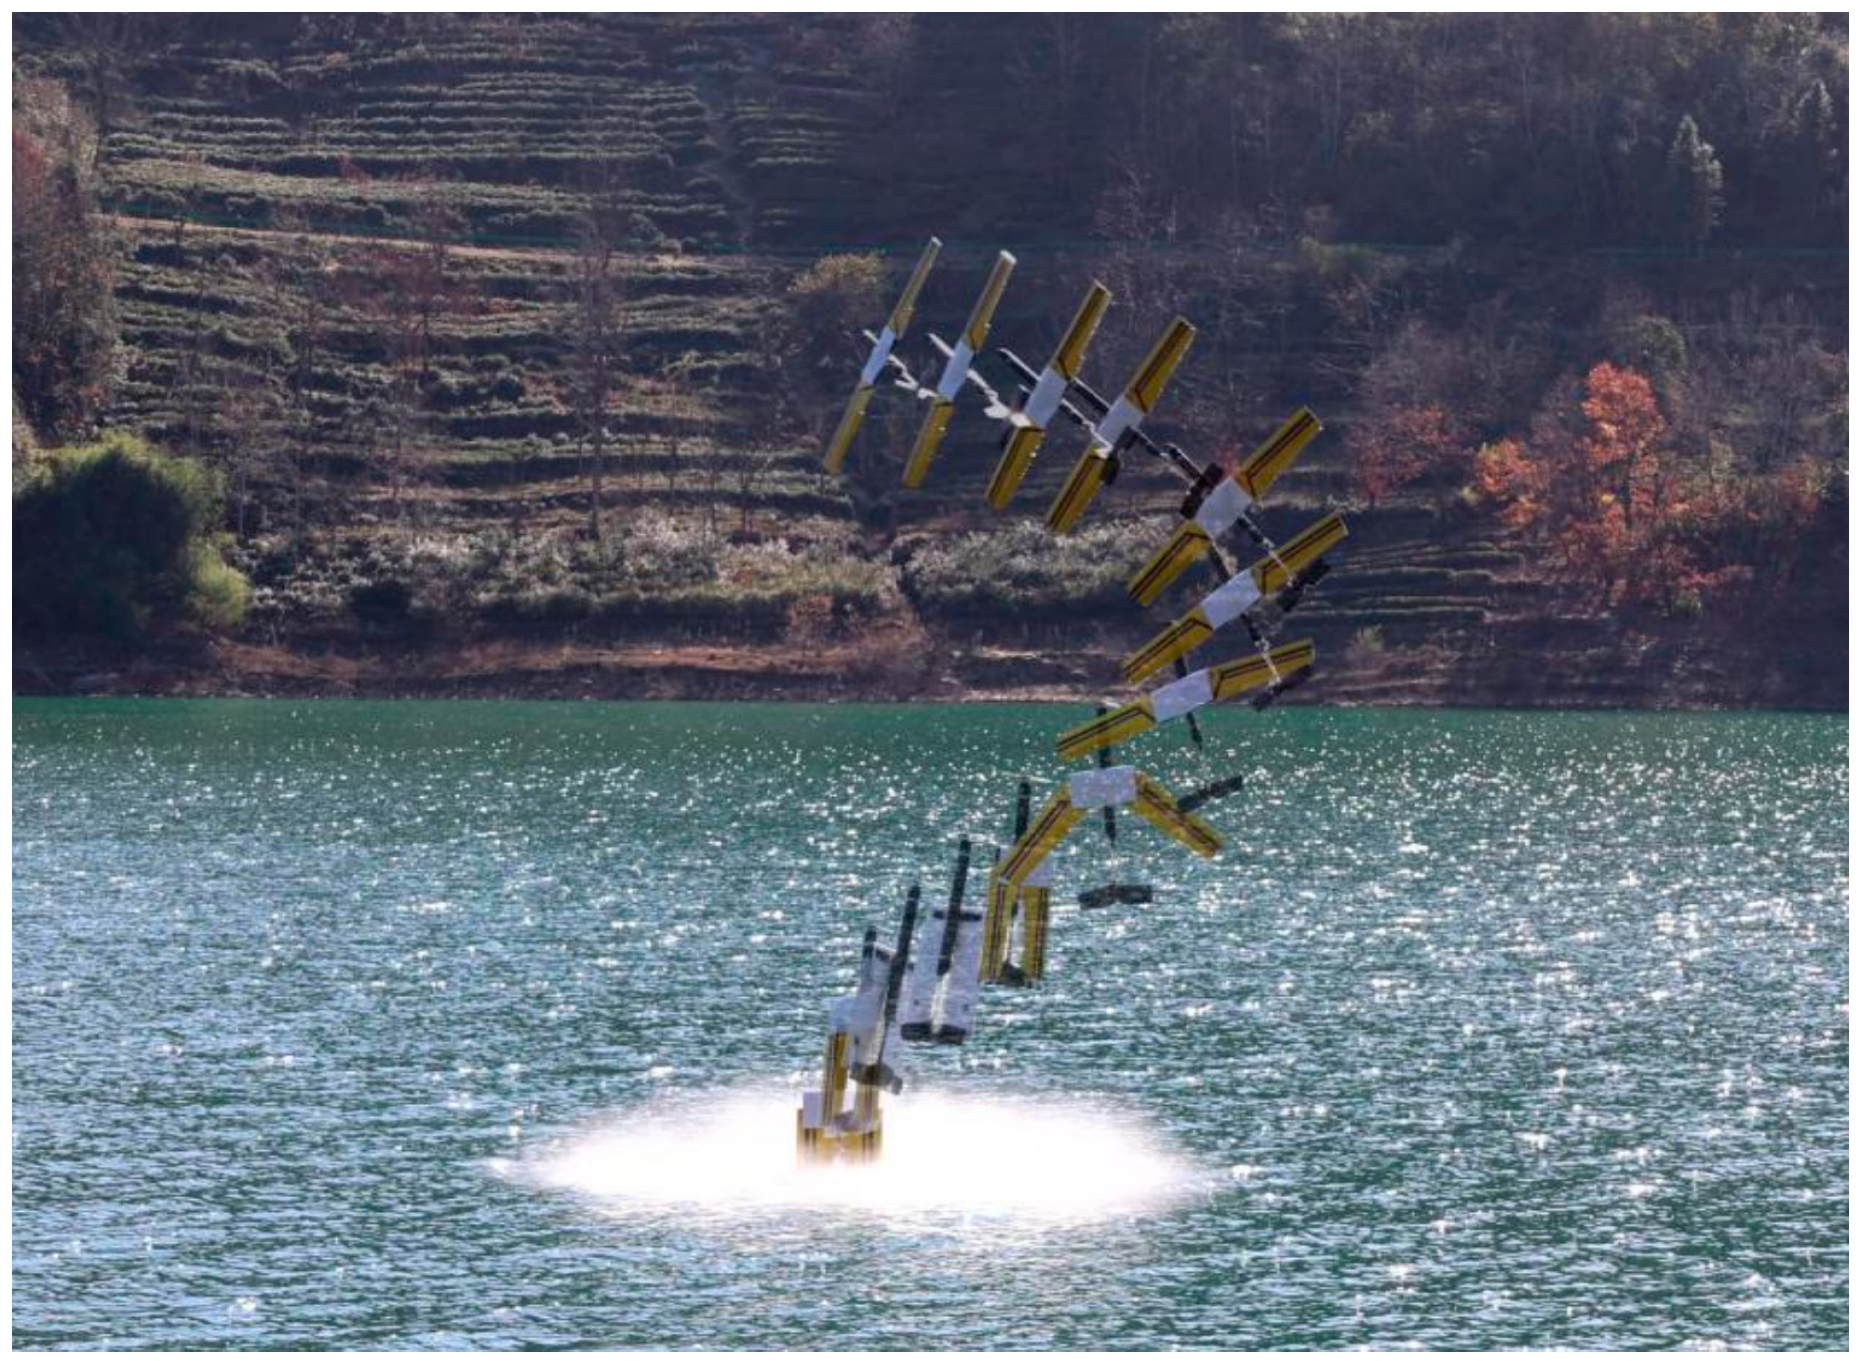
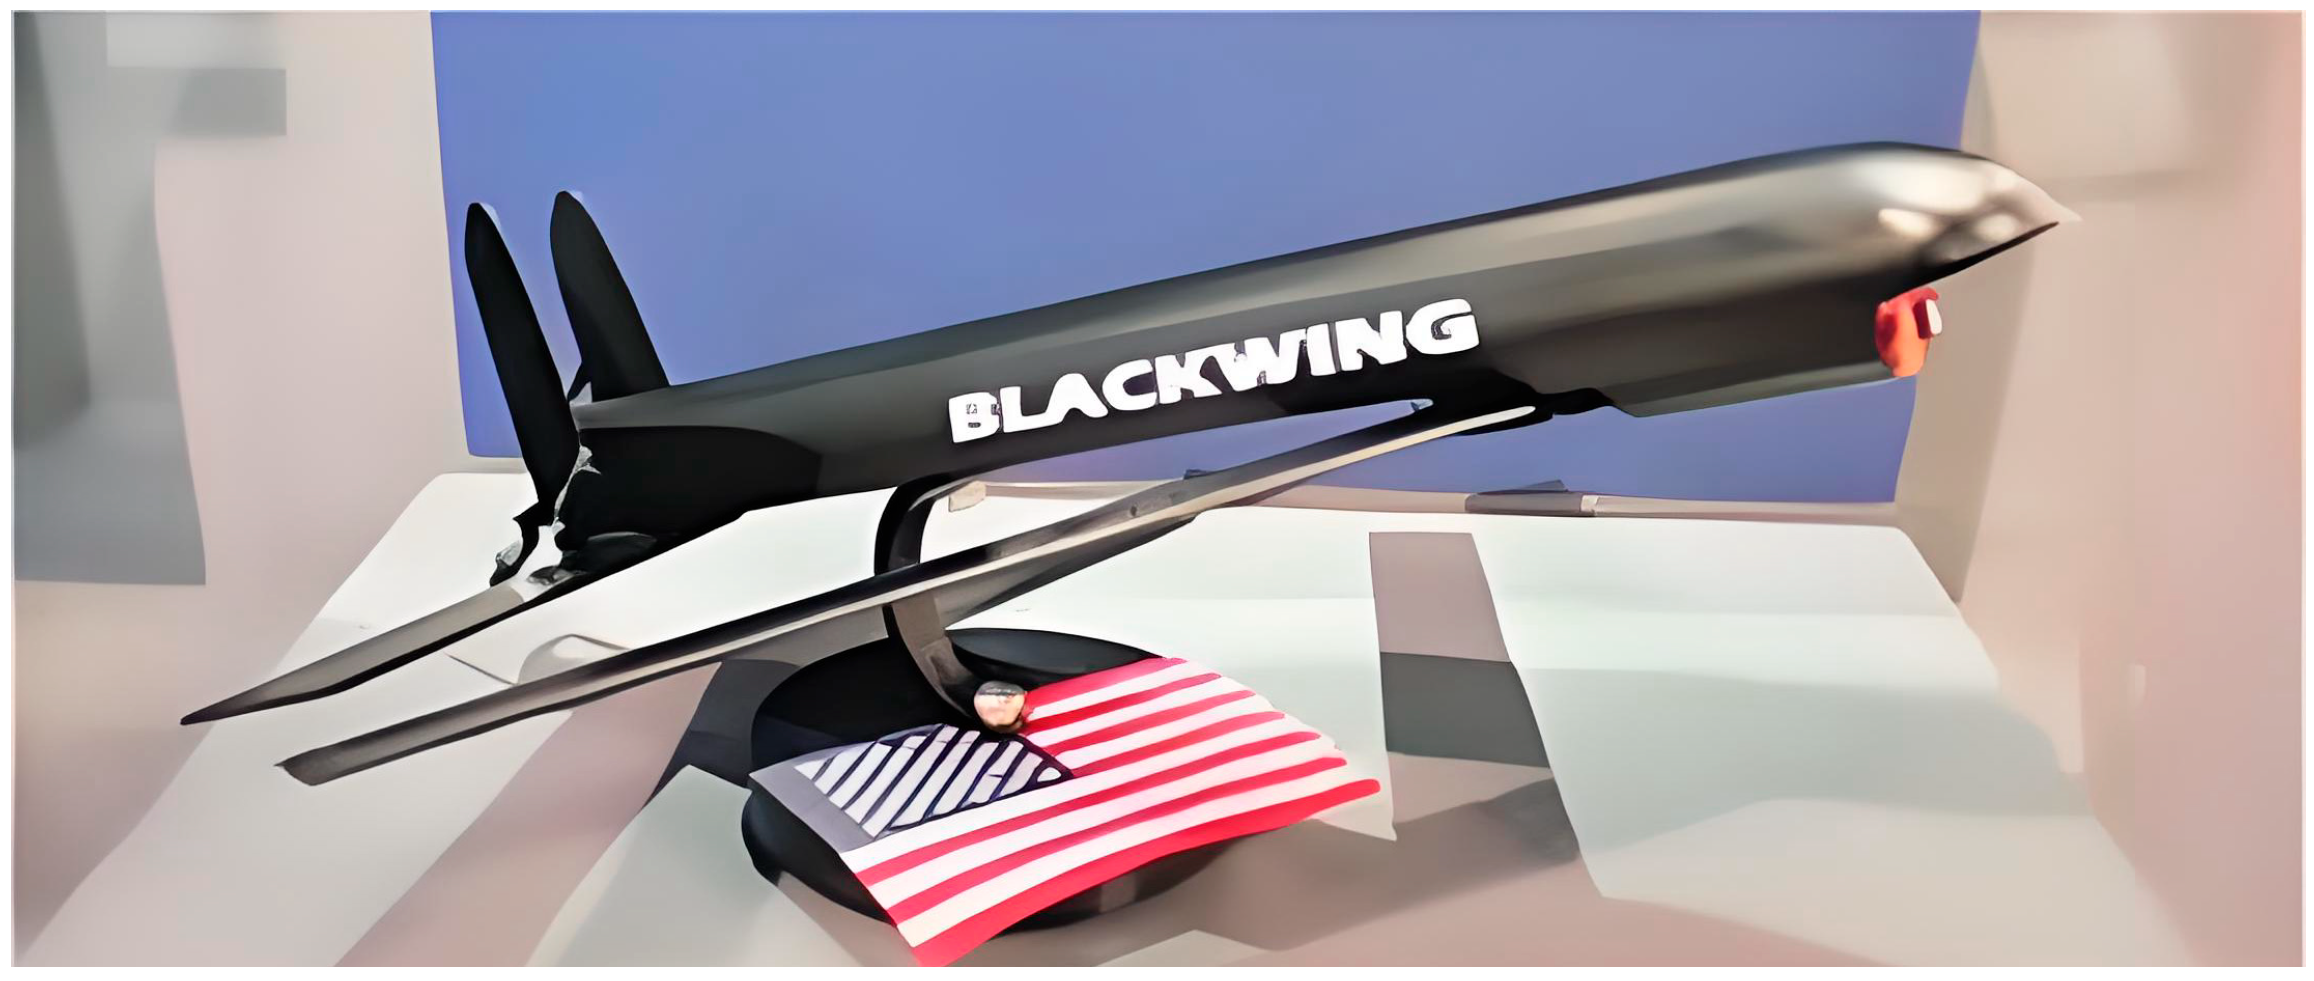
Advances in Folding-Wing Flying Underwater Drone (FUD) Technology


 ,
Highlights
- This review compares two main folding-wing configurations—lateral and longitudinal—assessing their trade-offs in terms of performance, efficiency, and structural complexity.
- It also evaluates dual-use and hybrid propulsion systems, emphasizing the challenges of integration, mass, and energy efficiency across different media.
- The study presents a comprehensive approach for High-Altitude Aerial Vehicles (FUDs), focusing on advanced materials, intelligent control systems, and innovations in energy to address existing challenges.
- It emphasizes the significant transformative potential of FUDs for both military and civilian use, urging targeted efforts to tackle critical bottlenecks and explore emerging technologies such as swarm operation and energy recovery.
Abstract
1. Introduction
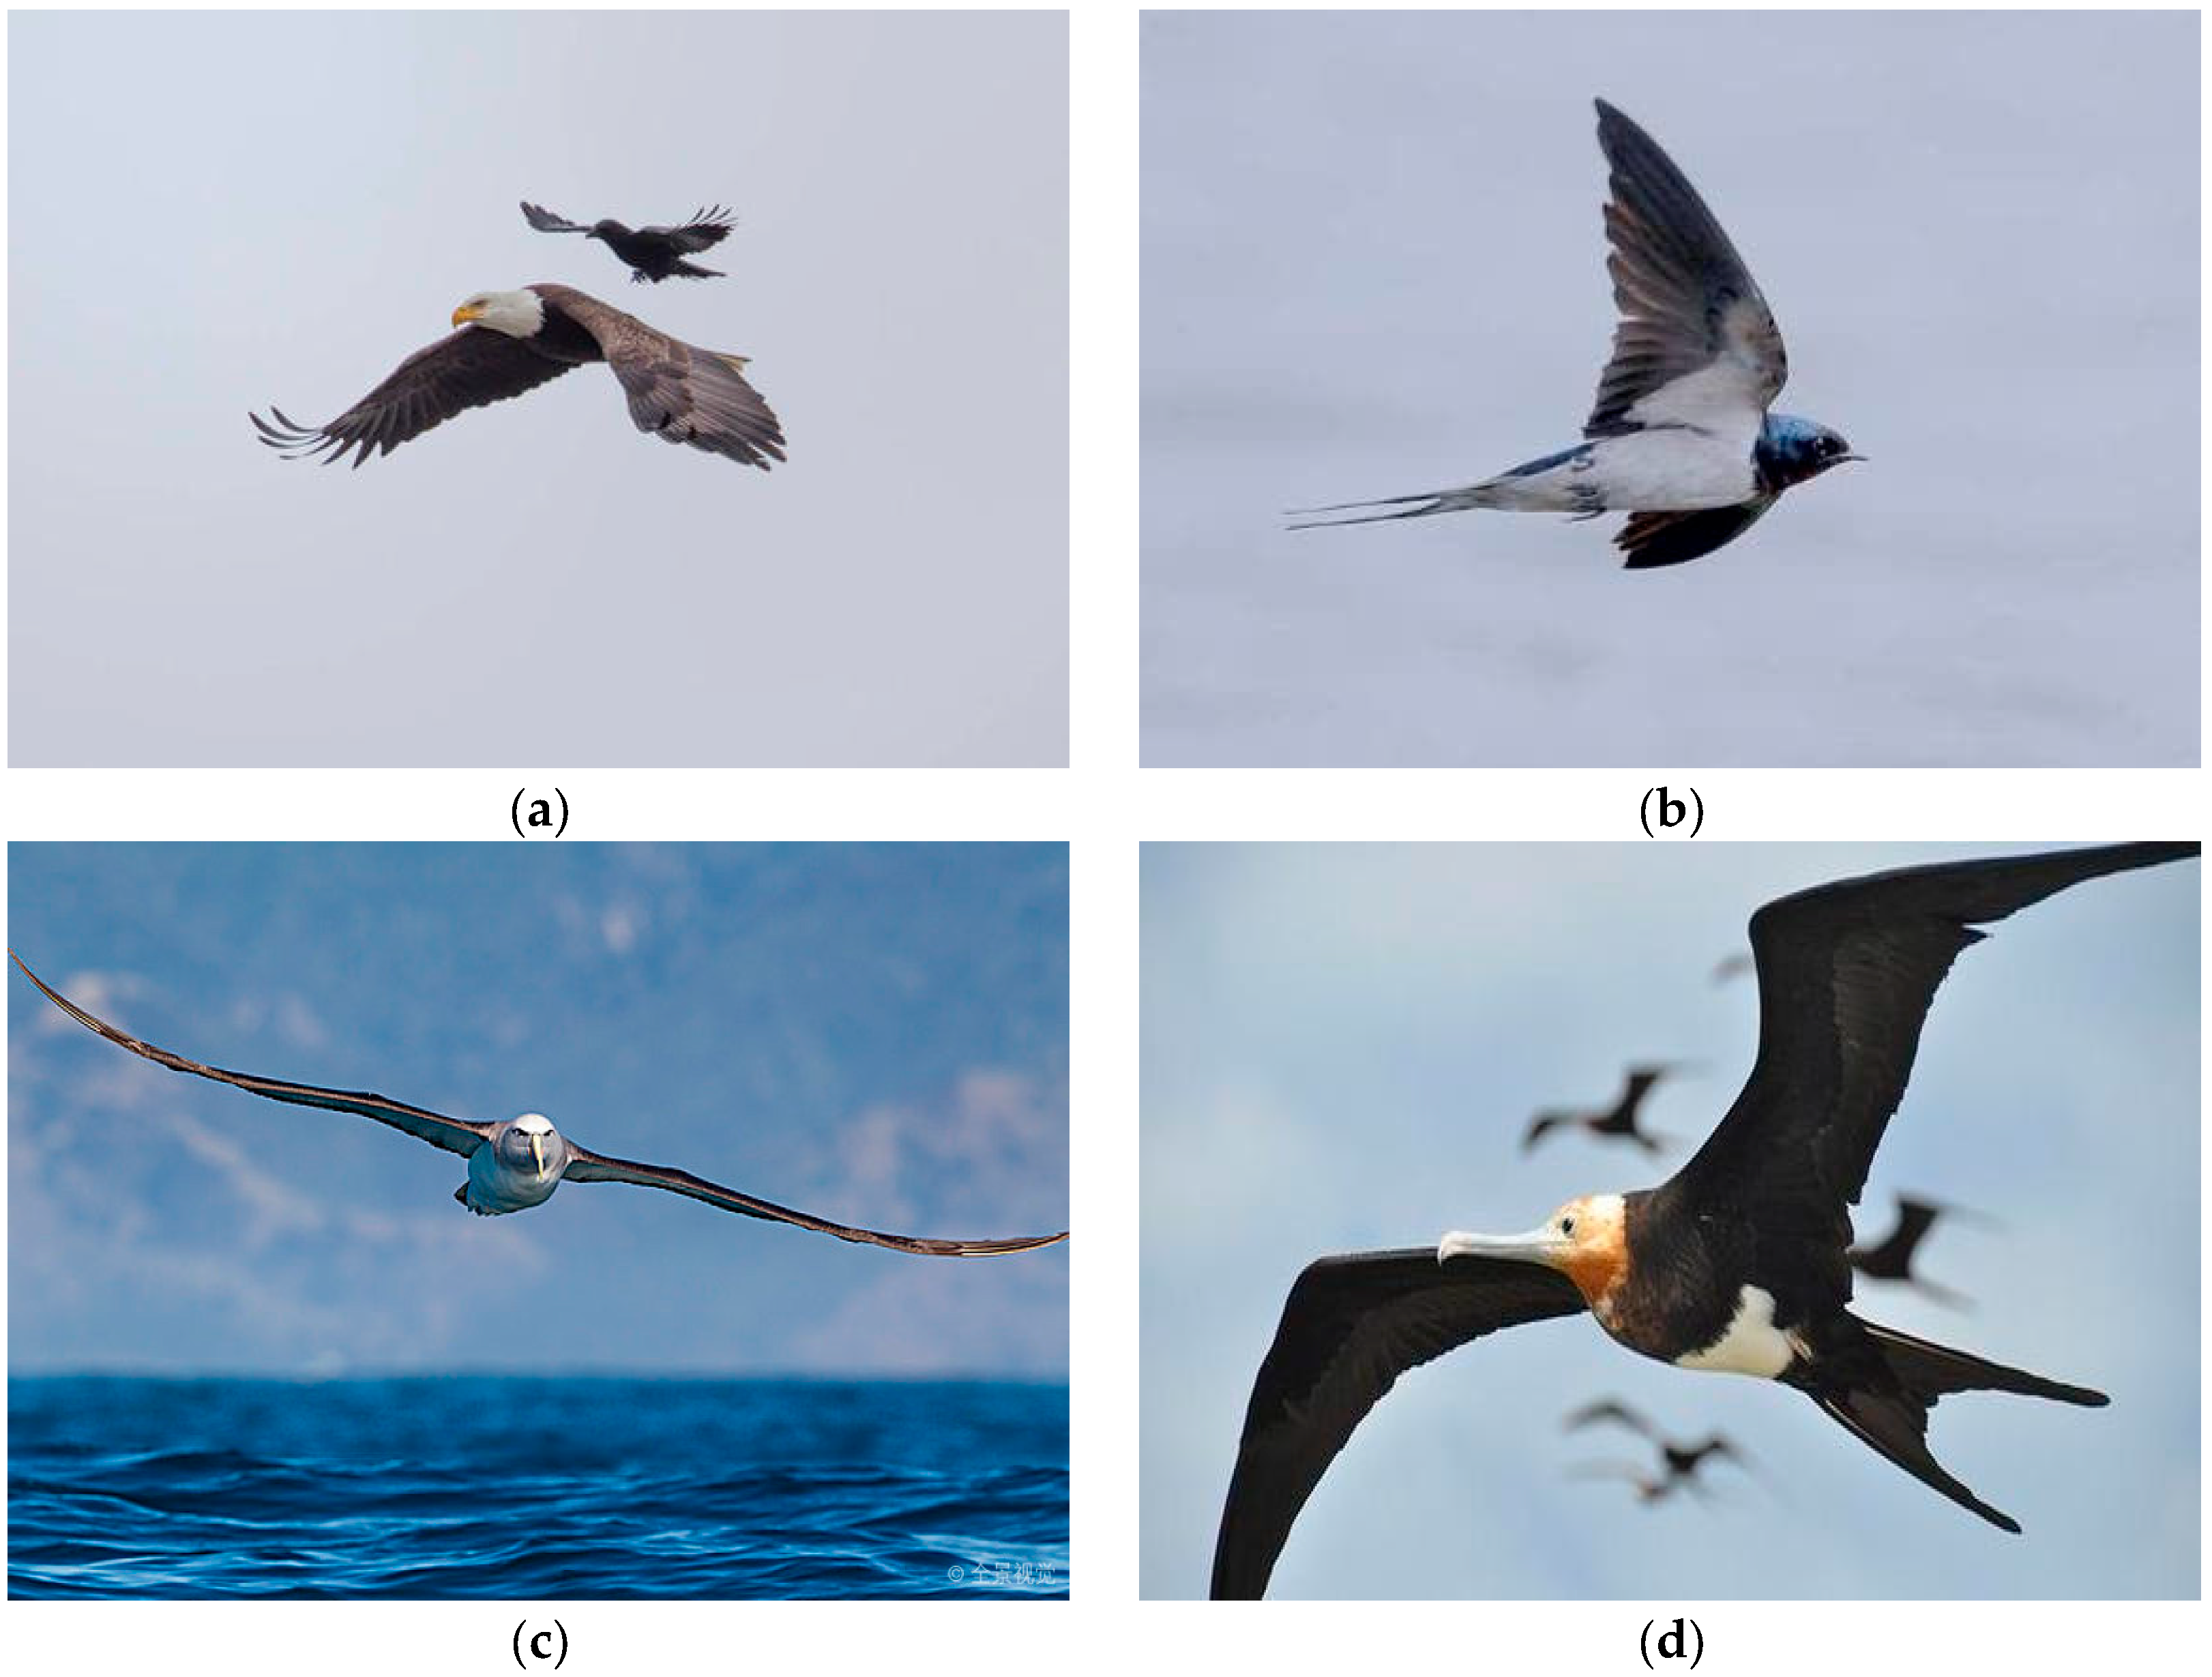
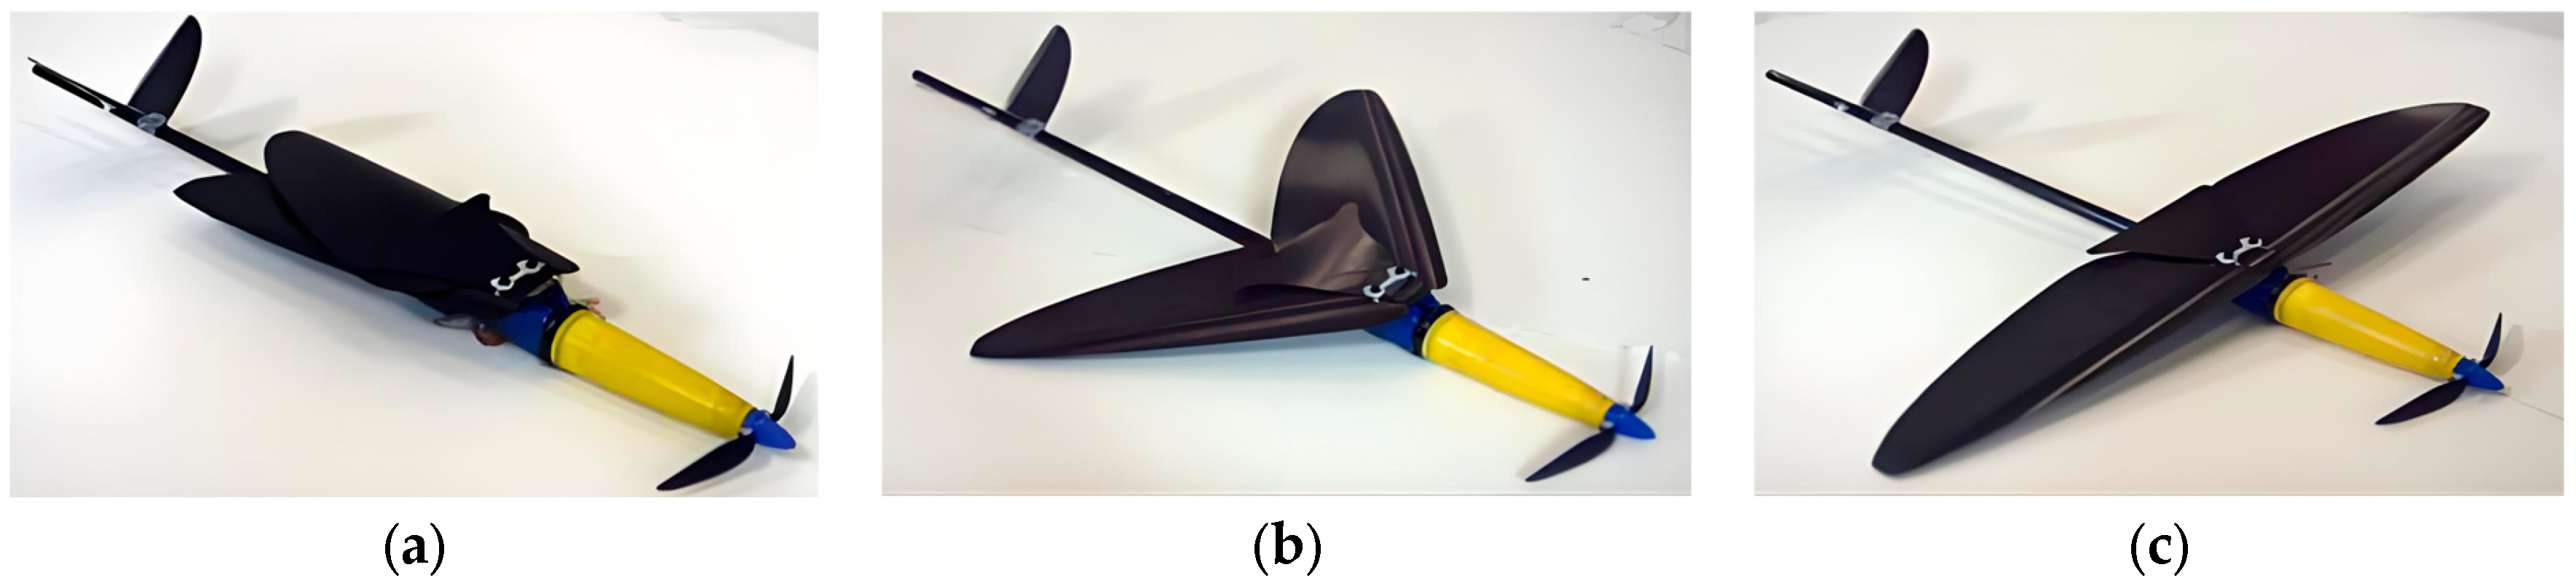
- Overall Layout: Given the starkly different physical media of air and water, the overall design of an FUD is essential for balancing aerodynamic and hydrodynamic performance through bionic and morphing technologies.
- Propulsion System: Current engine performance is significantly inadequate. The engine must provide efficient thrust in both air and water, or multiple systems must be integrated without incurring a prohibitive weight penalty.
- Dynamics Modeling and Control: FUDs must maintain stability amidst drastic dynamic changes and external disturbances; therefore, accurate models of multiphase fluid–structure interactions are needed to simulate the violent transition process and predict loads.
- Experimental Verification: A graduated testing regimen, from laboratory benches to open water, is essential to validate designs and models under complex sea condition disturbances.
2. Research Status of Folding-Wing FUD Technology
2.1. Lateral-Folding Wing FUD
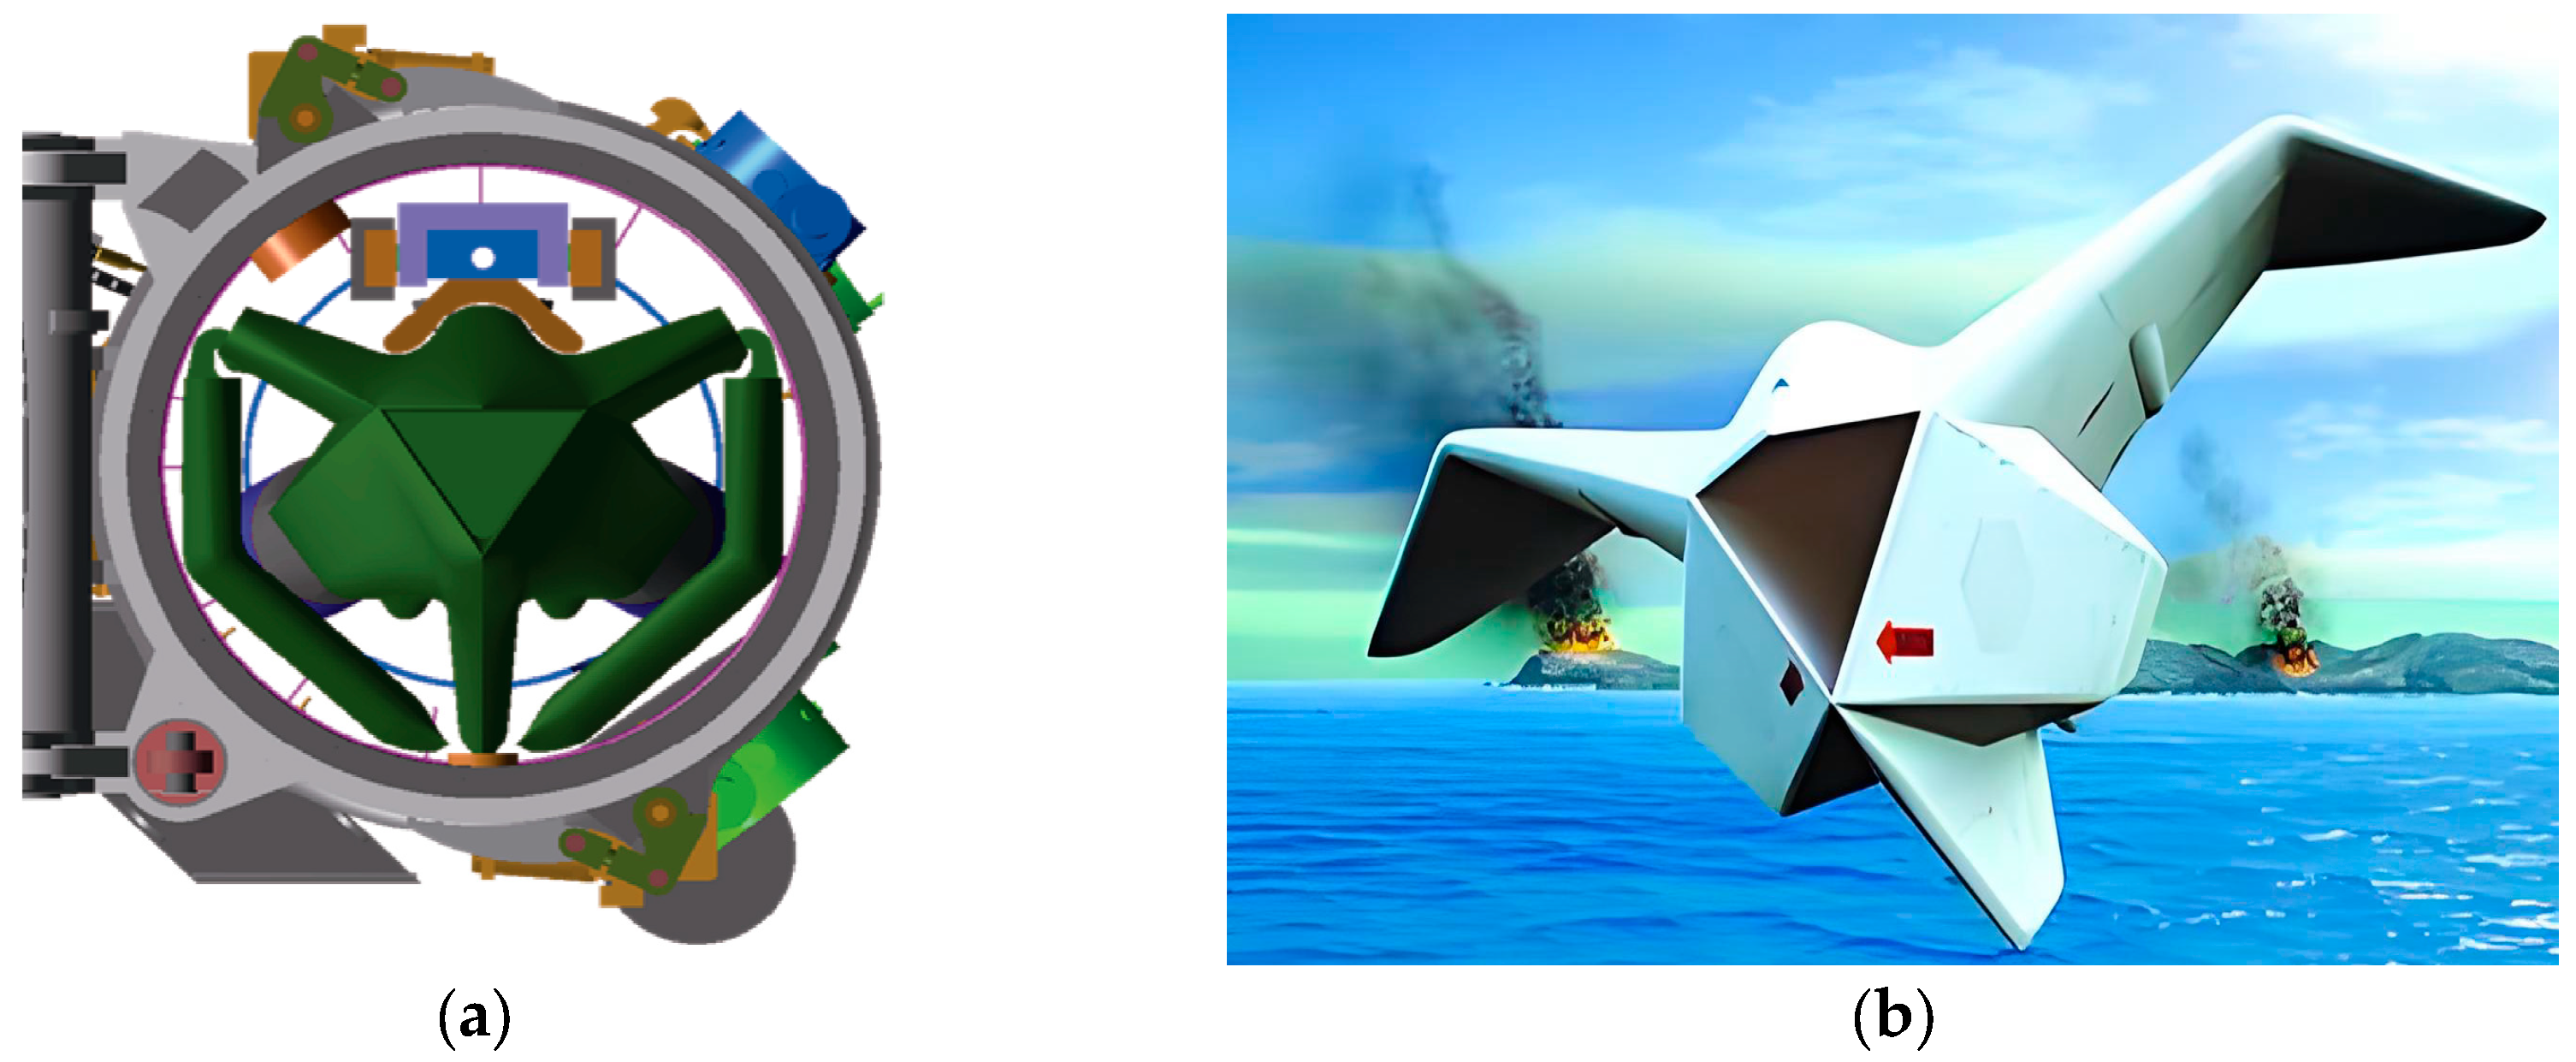
2.2. Longitudinal-Folding Wing FUD
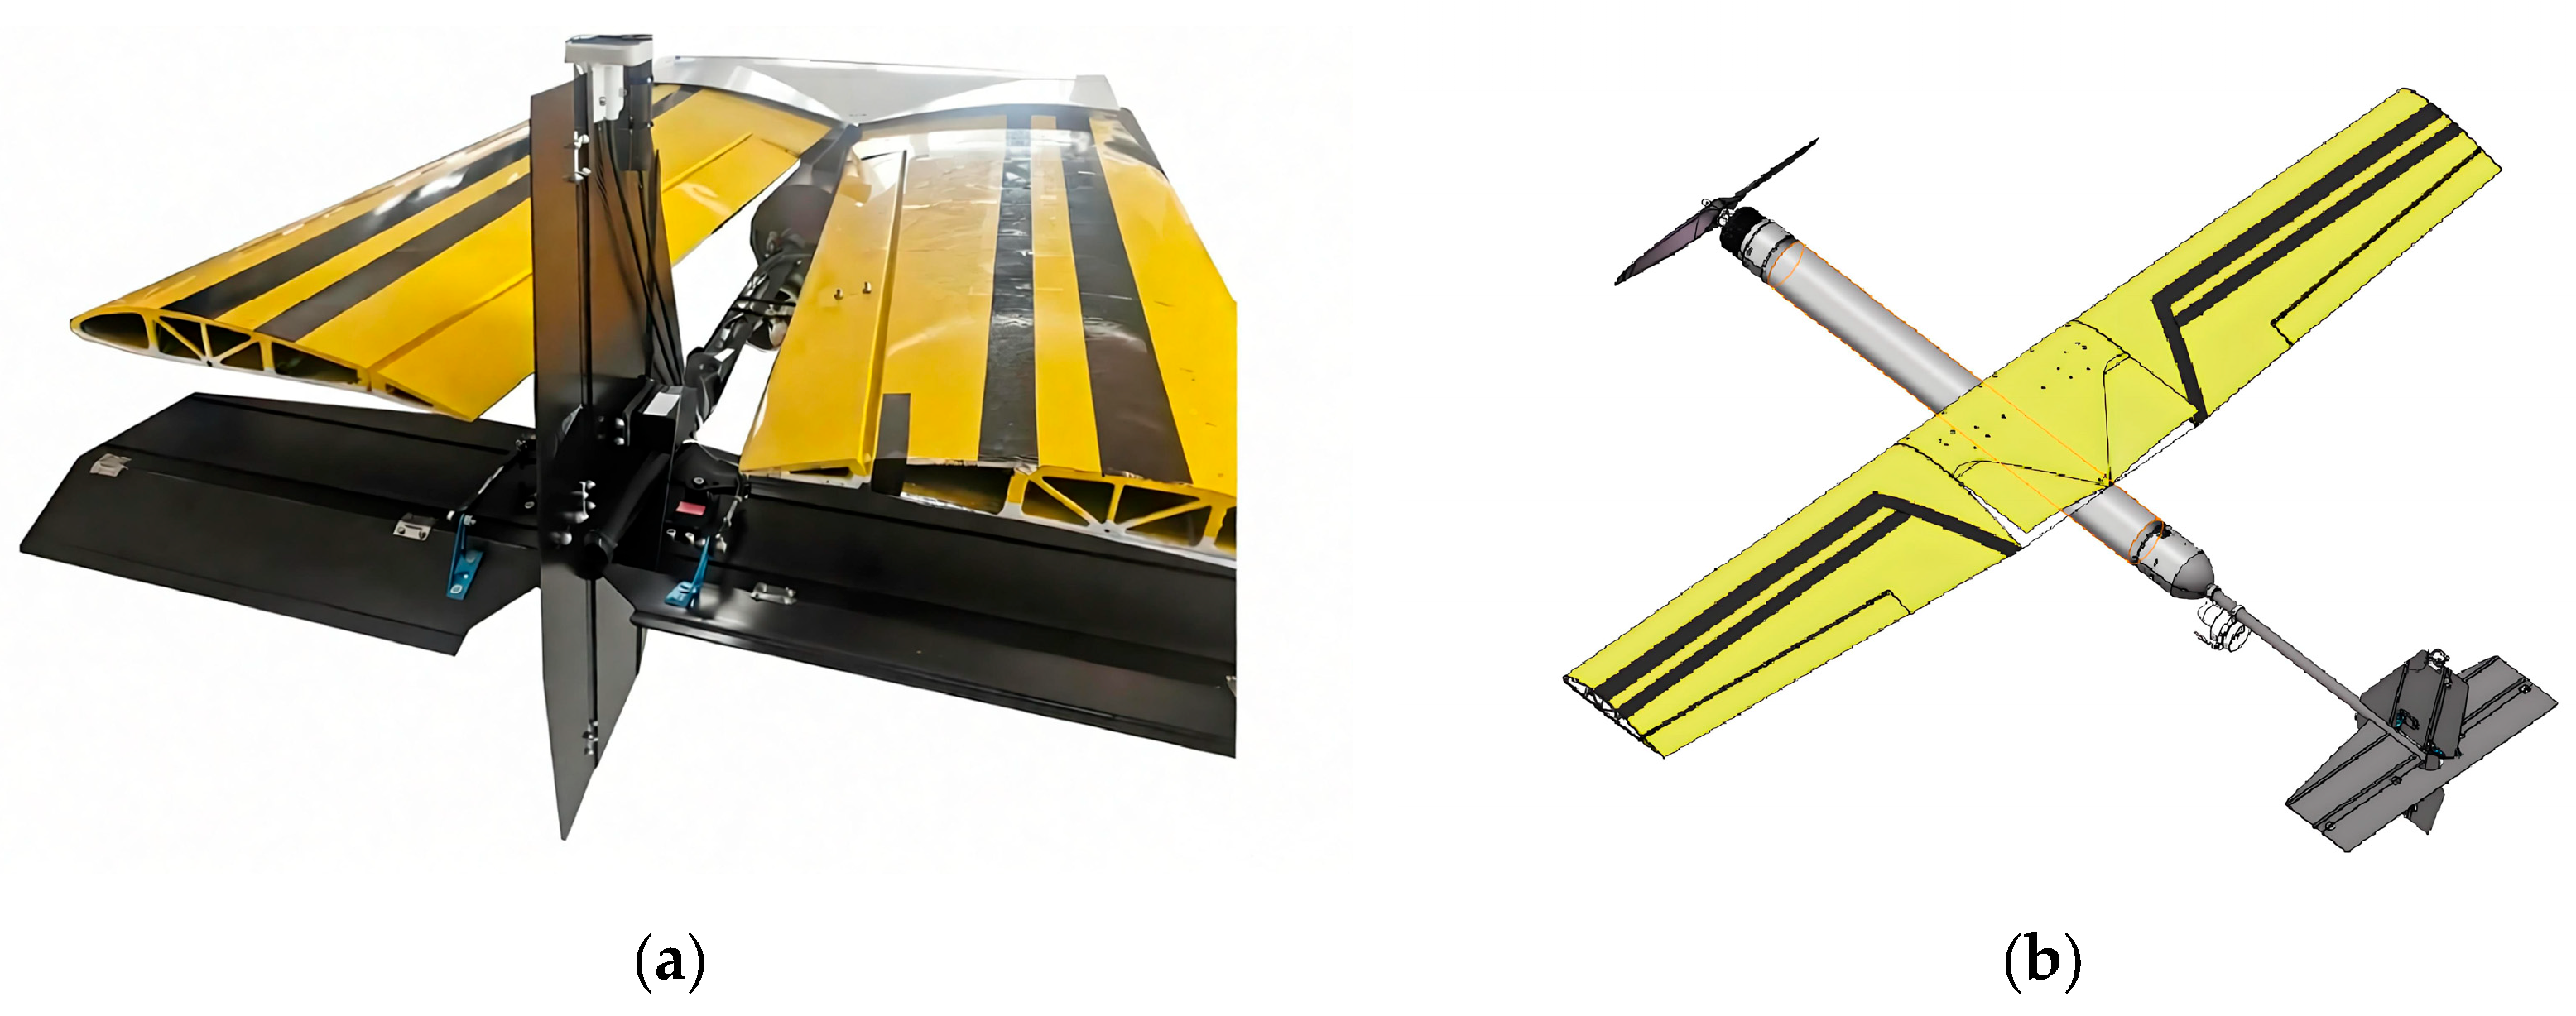
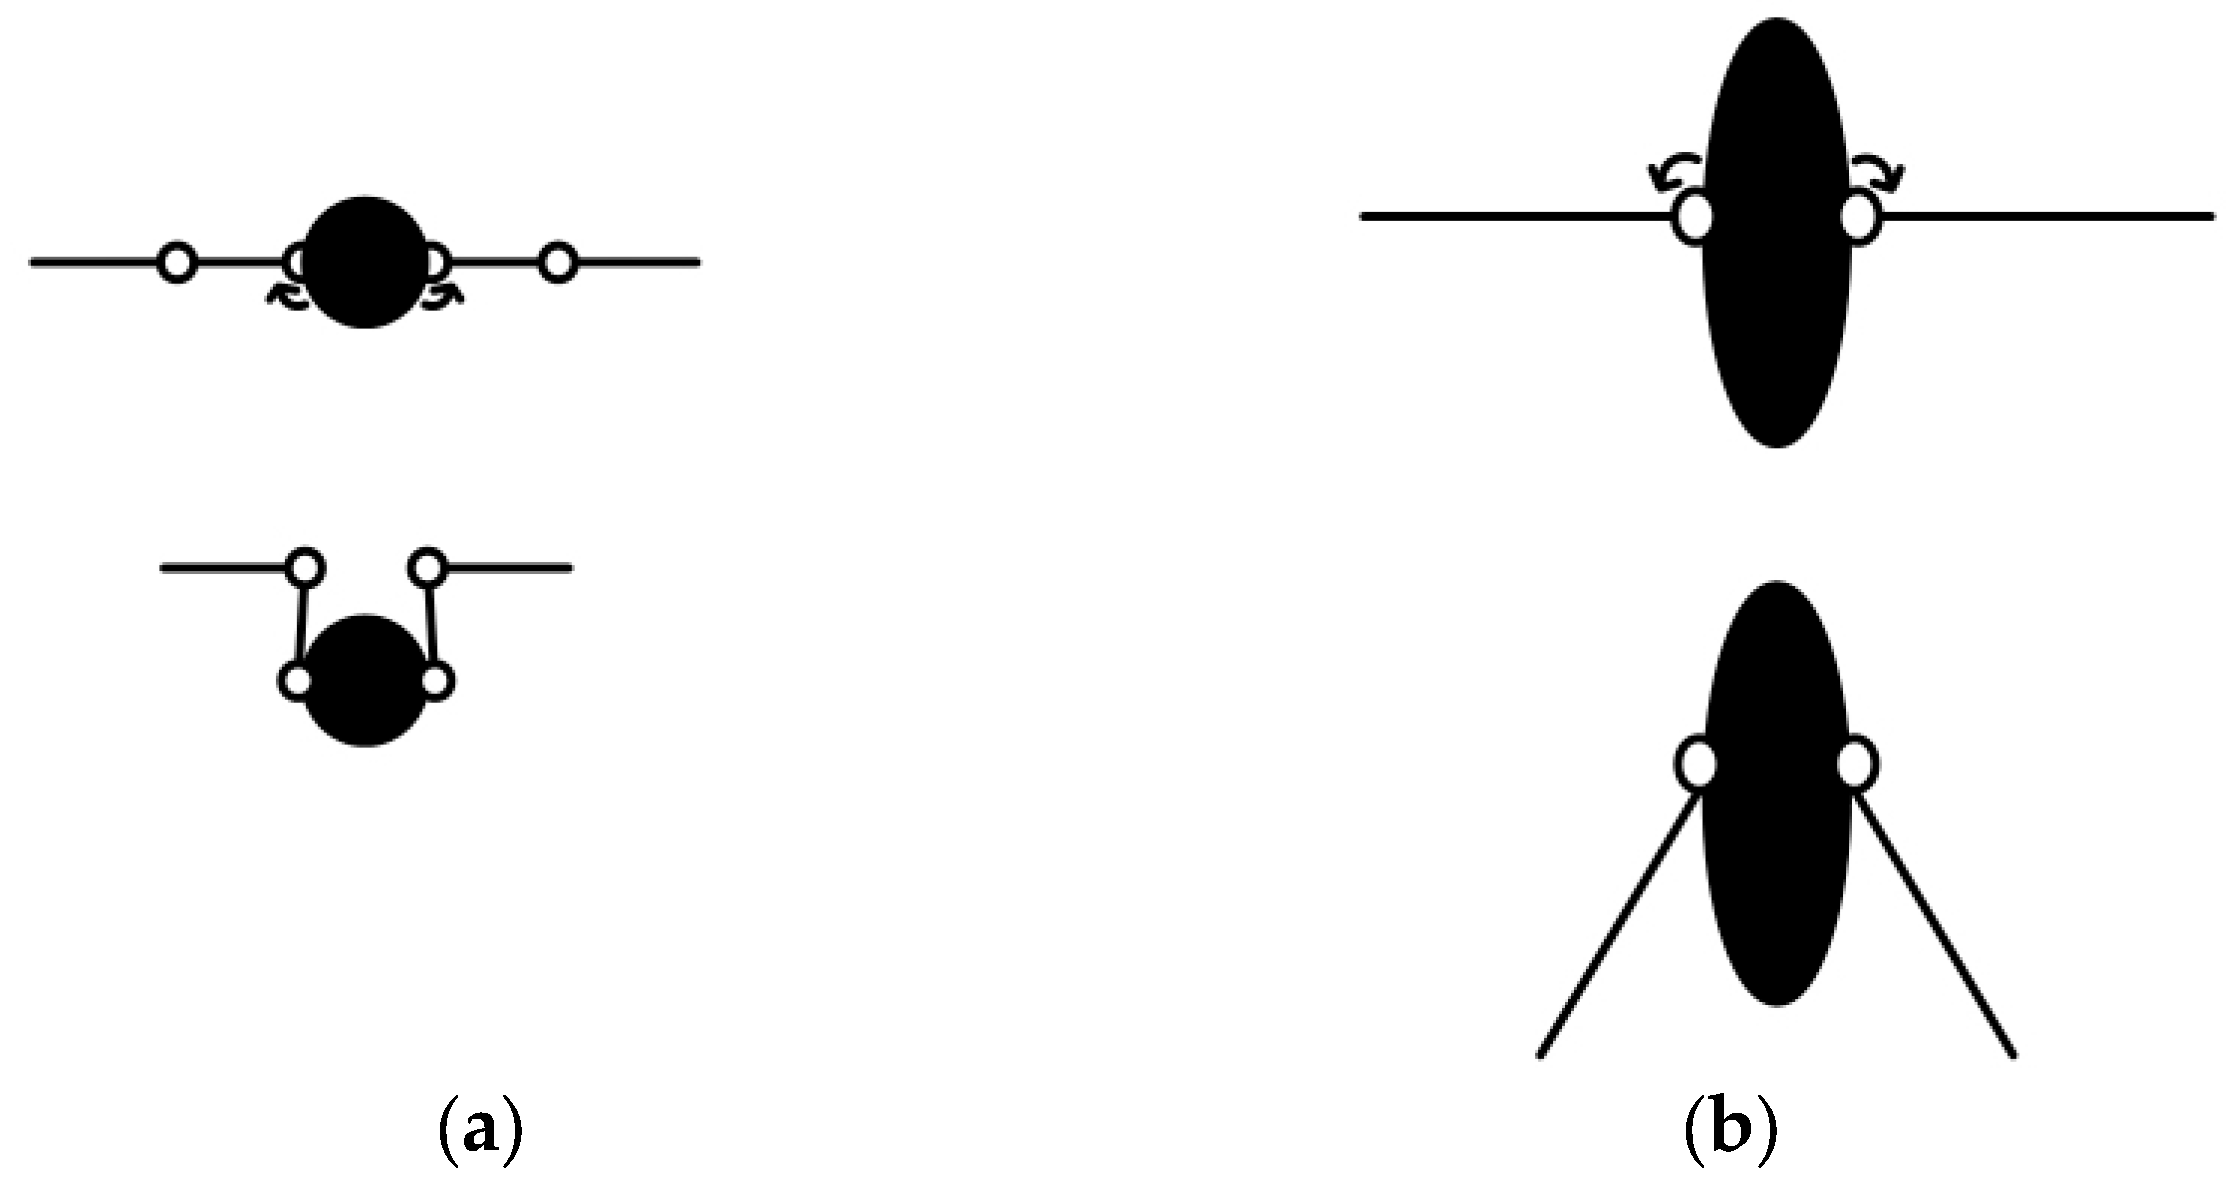
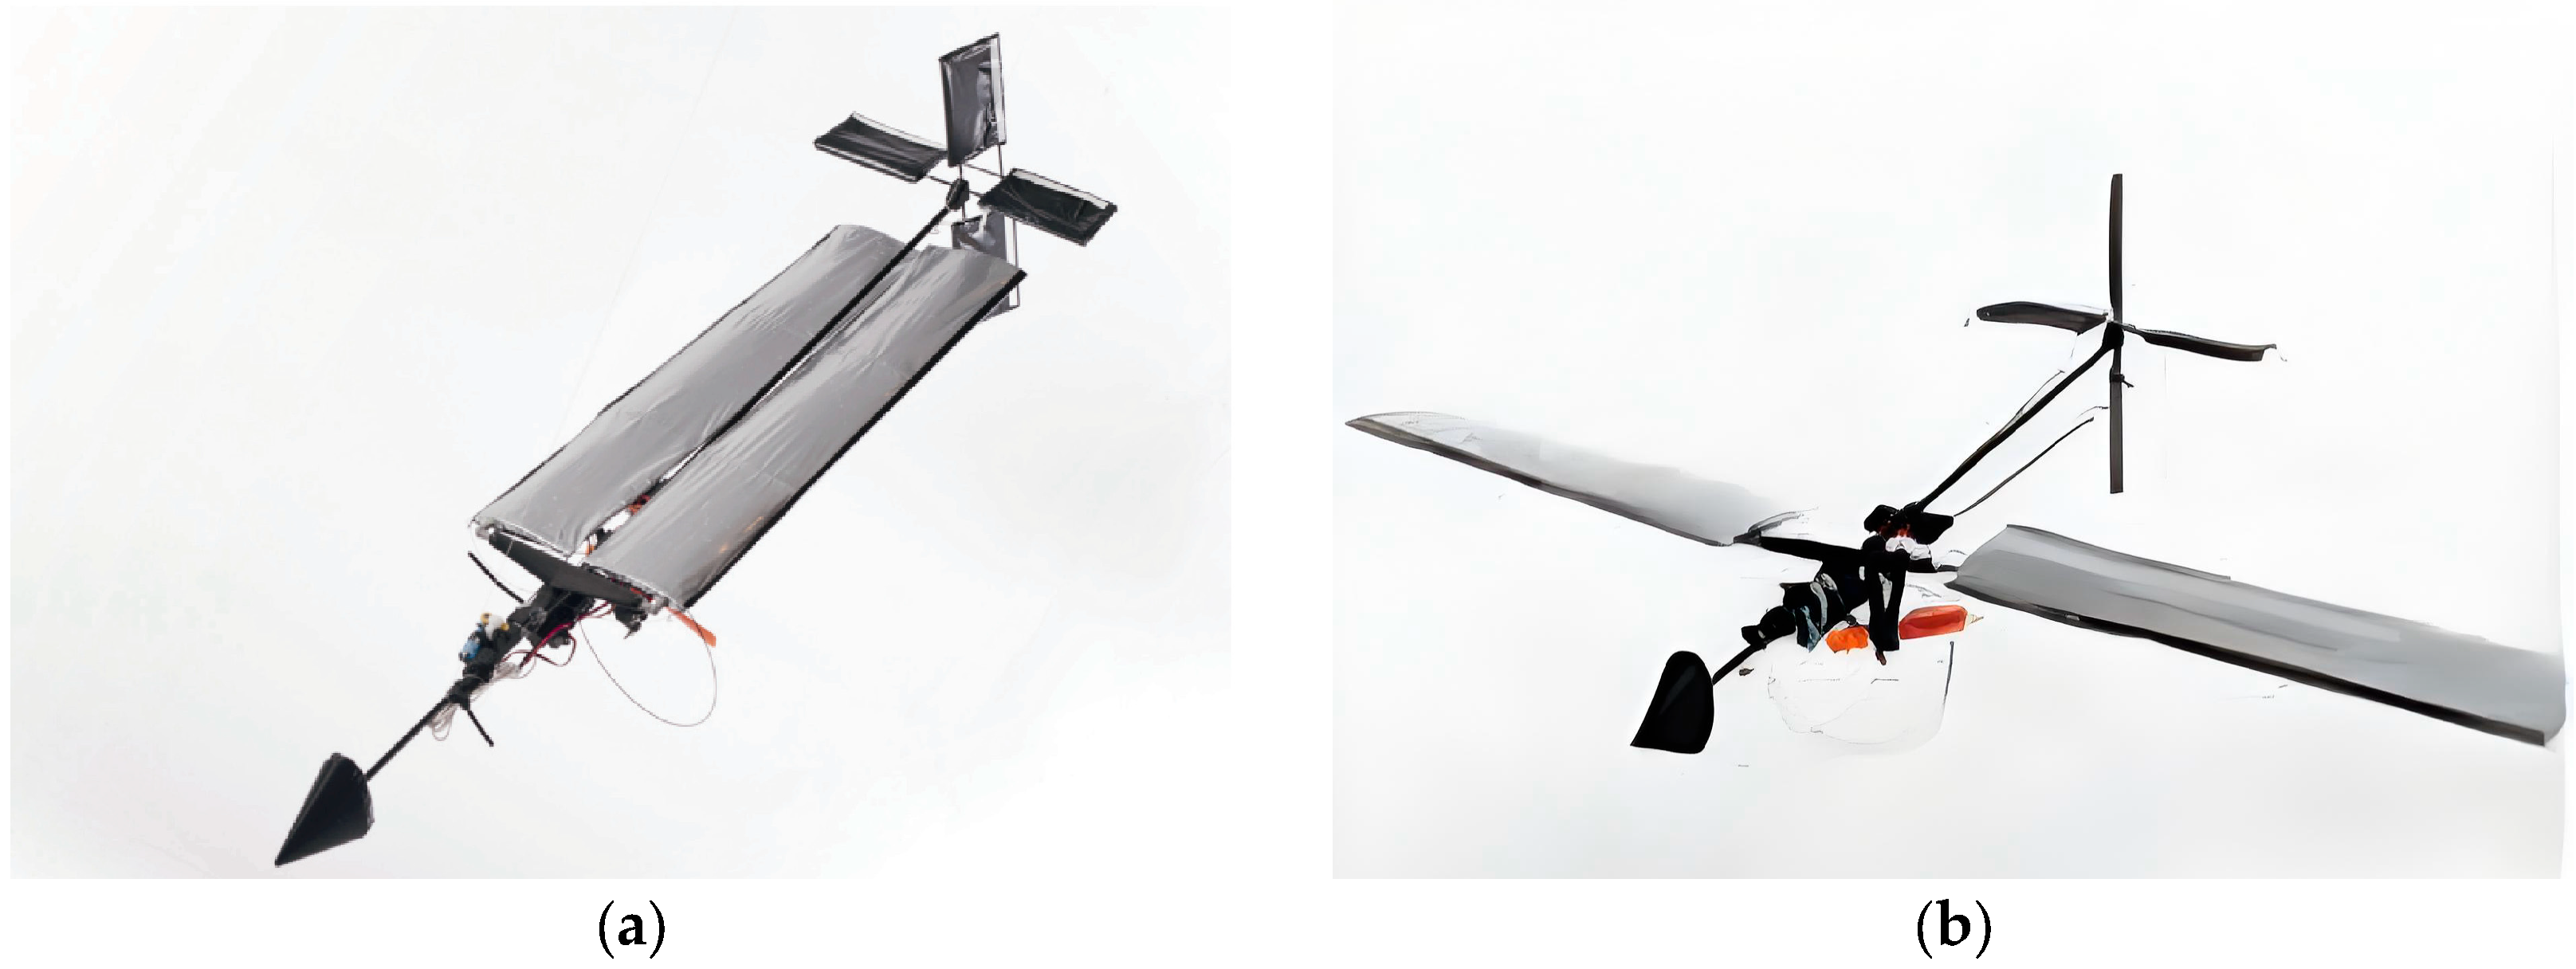
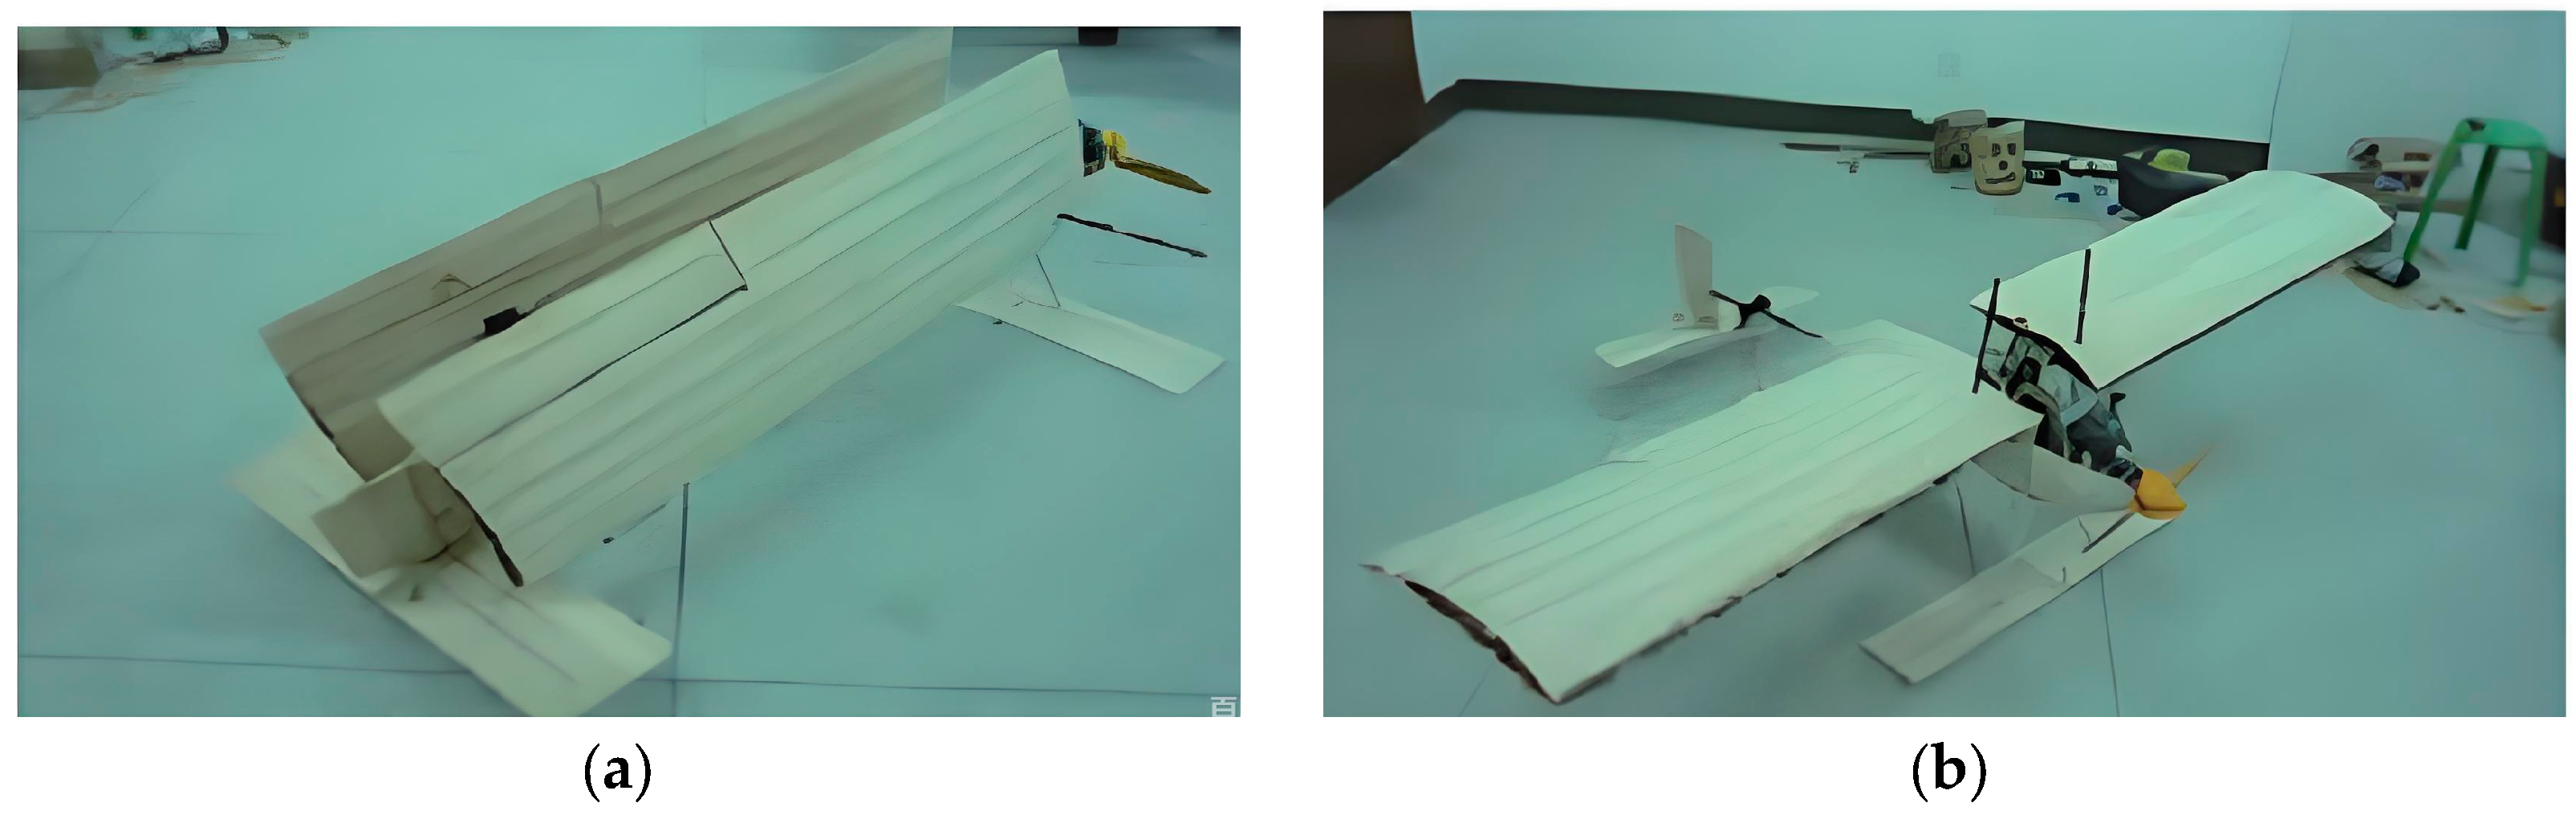
2.3. Comparison of Various Folding-Wing FUD
3. Propulsion System Technology
3.1. Air–Water Dual-Use Propulsion Systems
- Dual-use propeller technology: The key to dual-use propeller technology lies in airfoil design and material selection (see Figure 11). Traditional aerial propellers utilize high-lift-to-drag-ratio airfoils, such as NACA 2412, which results in low efficiency underwater. Traditional underwater propellers use thick airfoils, such as NACA 66, which cause high drag during aerial flight. To resolve this, Johns Hopkins University proposed a variable-section propeller solution in 2018. The blade root adopts an underwater-adapted airfoil 15% thickness, the mid-section a transitional airfoil 10% thickness, and the tip an aerial-adapted airfoil 8% thickness. Through CFD optimization, this propeller achieved an aerial propulsion efficiency of 0.75 and an underwater efficiency of 0.65, a 20% improvement over traditional single-airfoil propellers. In 2019, the National University of Singapore employed carbon fiber-reinforced polyether ether ketone CF/PEEK for its propellers. This material has a density of 1.4 g/cm3 and a tensile strength of 1.2 GPa, capable of withstanding pressures at a depth of 30 m, approximately 0.3 MPa, and exhibiting excellent corrosion resistance, with no significant degradation after 500 h in a salt spray environment. The propeller features a swept-back design, operating at 2000 rpm during aerial cruise and 800 rpm during underwater navigation. Motor speed adjustment enables multimedia adaptation, but the high cost limits mass production [43].

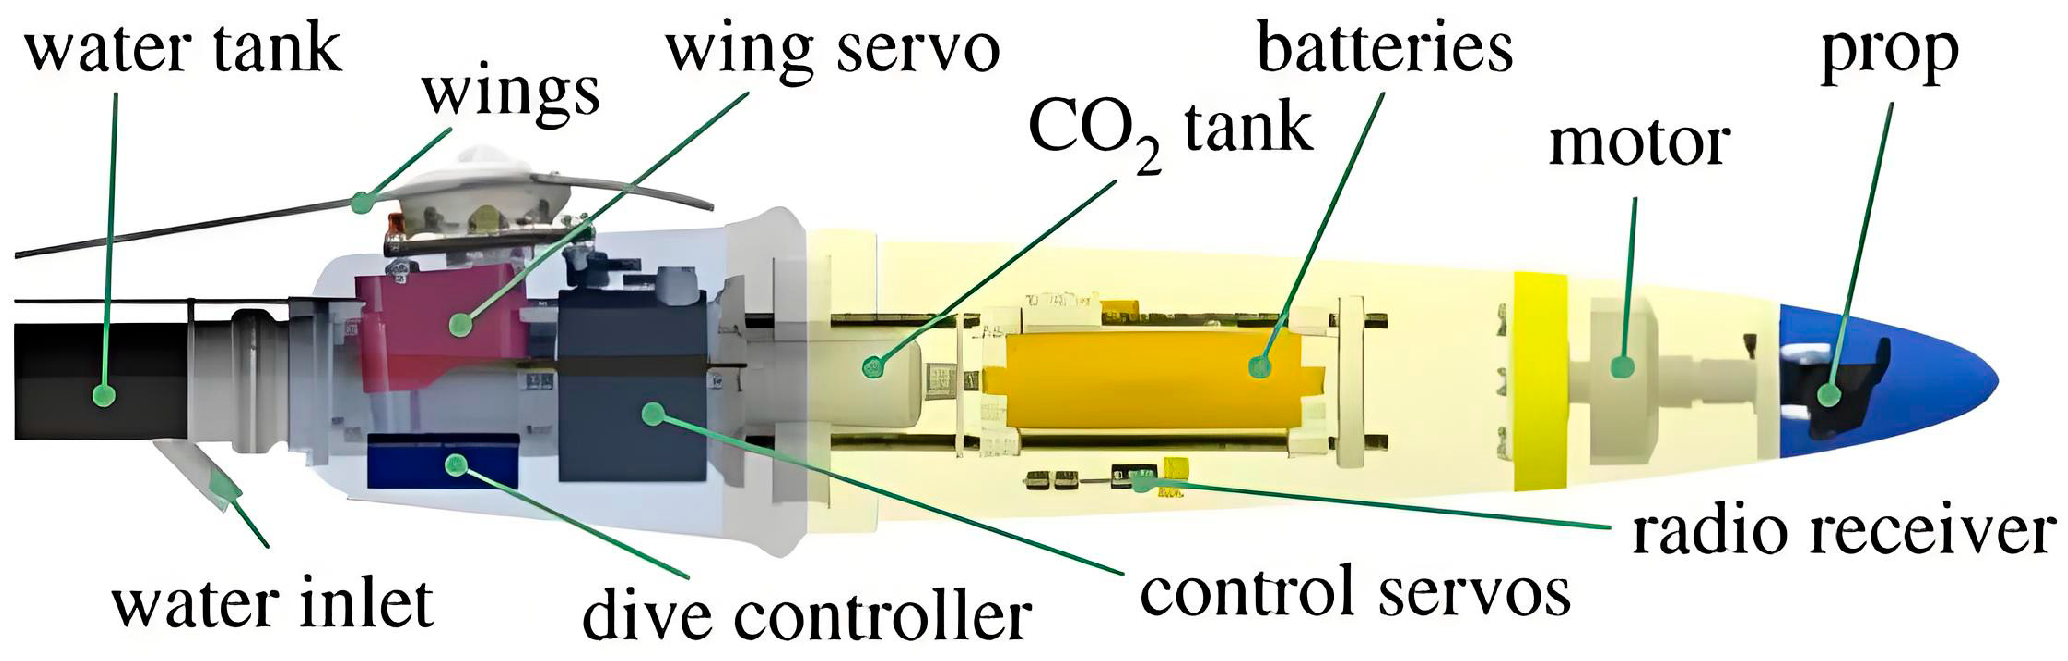
- Advanced electric propulsion: For power sources, electric propulsion is the primary choice due to its simple structure and convenient speed control. However, traditional lithium batteries have a low energy density, which limits their endurance. In 2017, Harvard University adopted a hydrogen-oxygen fuel cell and a water electrolyzer regeneration system. The fuel cell extends aerial endurance from 10 min with lithium batteries to 30 min. Underwater, electrolysis produces hydrogen and oxygen for fuel cell regeneration; however, the process consumes significant energy, making it suitable only for micro-FUDs [45,46].
- Metal-fuel engines: Metal-fuel engines are a potential direction for large-sized FUD (see Figure 12). Liu proposed an aluminum-water reaction engine that uses aluminum powder as fuel and seawater as the oxidizer, providing continuous thrust. The engine operates via hydrogen-oxygen combustion in air and an aluminum-water reaction underwater, far exceeding that of lithium batteries. However, challenges remain in achieving uniform mixing of aluminum powder with seawater and in expelling the reaction product alumina. Currently, only ground tests have been conducted at 100 N thrust for 5 min [47,48].

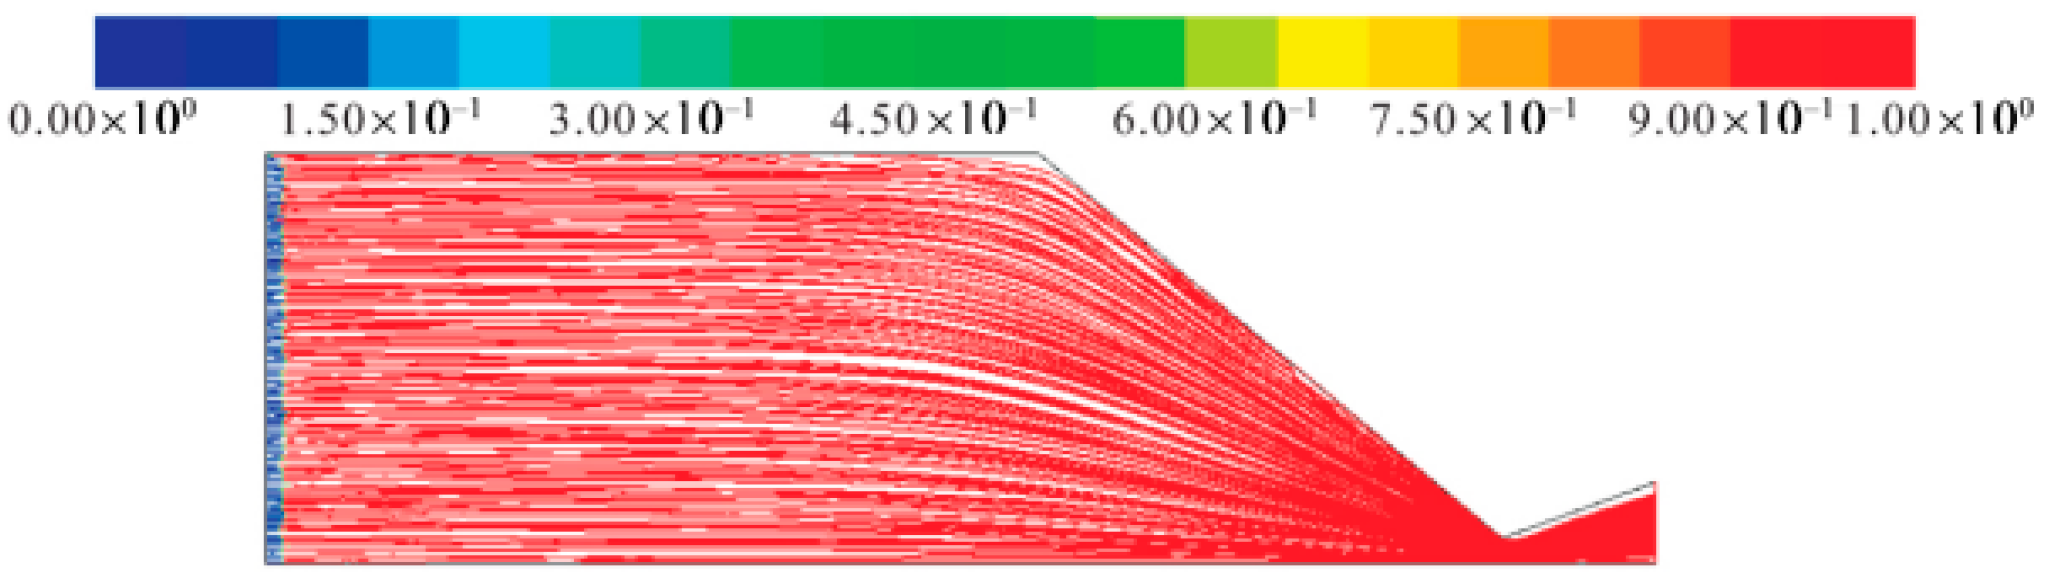
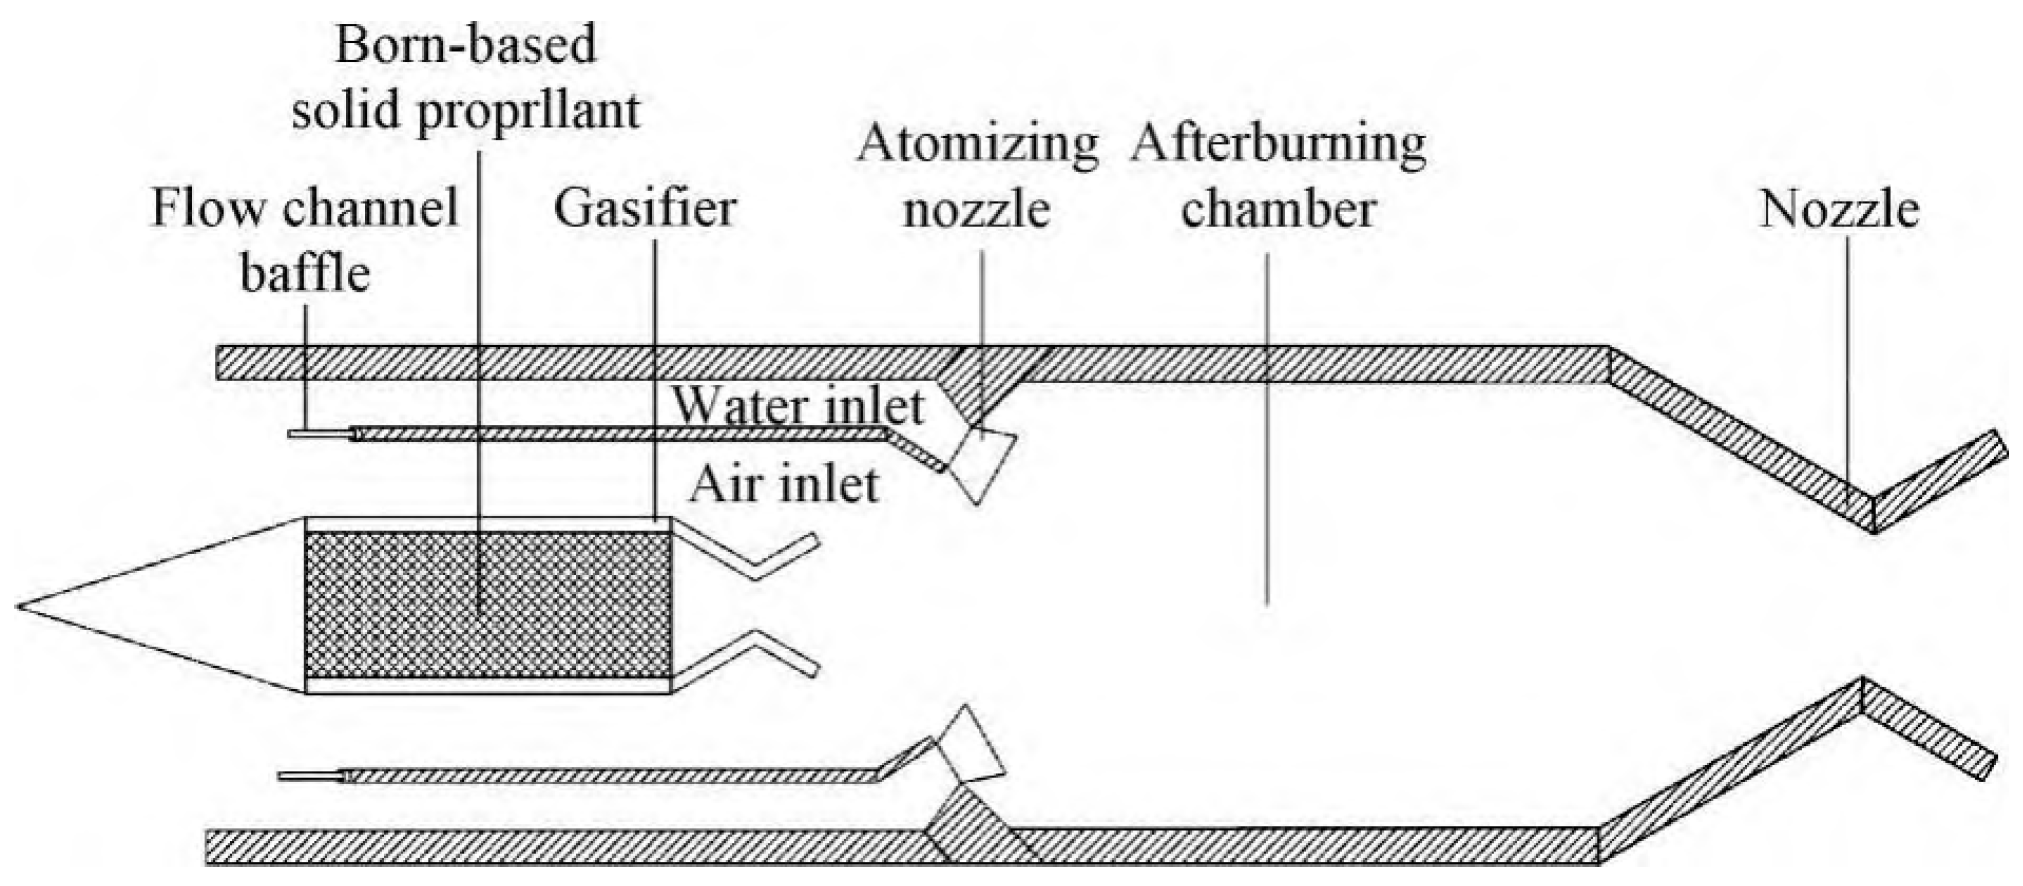
- Ramjet engine: The National University of Defense Technology has proposed a cross-media ramjet engine scheme (see Figure 13). This power scheme enables the integration of air and underwater power units, allowing for high-speed navigation of aircraft at all stages of flight. This power system utilizes a metal-based oxygen-poor propellant as its primary fuel. It is primarily composed of components such as the air inlet, water inlet pipeline, gas generator, supplementary combustion chamber, and tail nozzle. Metal-based oxygen-poor propellants burn in the gas generation chamber to produce rich combustion gas. During the flight phase in the air, the produced flame-retardant gas reacts with the air entering the air intake in the supplementary combustion chamber and is sprayed out by the nozzle to provide thrust. During the underwater navigation stage, the metal particles in the rich combustion gas produced react with the seawater entering through the water inlet pipeline in the supplementary combustion chamber. On the one hand, the reaction generates hydrogen gas, which is discharged through the nozzle to generate thrust. On the other hand, the reaction releases heat, causing the water working medium in the secondary water inlet to evaporate and expand, doing work and generating thrust. The power scheme can achieve a high-altitude cruise Mach number of 2.5, a sea-crossing Mach number of 2.3, and an underwater navigation speed of 141 m/s. Currently, the power scheme for water-air dual-purpose ramjet engines remains in the conceptual design stage. Although the feasibility of this power system scheme has been theoretically demonstrated, several key technologies still need to be addressed before it can be applied in practical engineering [50].

3.2. Hybrid Propulsion Systems
4. Dynamics Modeling and Control Technology
4.1. Multi-Phase Flow Dynamics Modeling and Control
- Aerial flight phase: The dynamics during aerial flight can be described using a 6-DOF model applicable to conventional fixed-wing aircraft, emphasizing lift, drag, and pitching moment coefficients. Tang developed an aerodynamic model based on wind-tunnel data, in which these coefficients are functions of Mach number and angle of attack, with a model error of less than 5% [59].
- Underwater navigation phase: For underwater operation, the dynamic model must incorporate hydrodynamic forces such as viscous drag, inertial forces, and added-mass effects. Hou established a 6-DOF model grounded in potential flow theory, integrating added-mass coefficients to capture the influence of water on vehicle motion. These coefficients were validated through water-tunnel experiments, demonstrating an error of less than 8% across speeds ranging from 0.5 to 5 m/s [17].
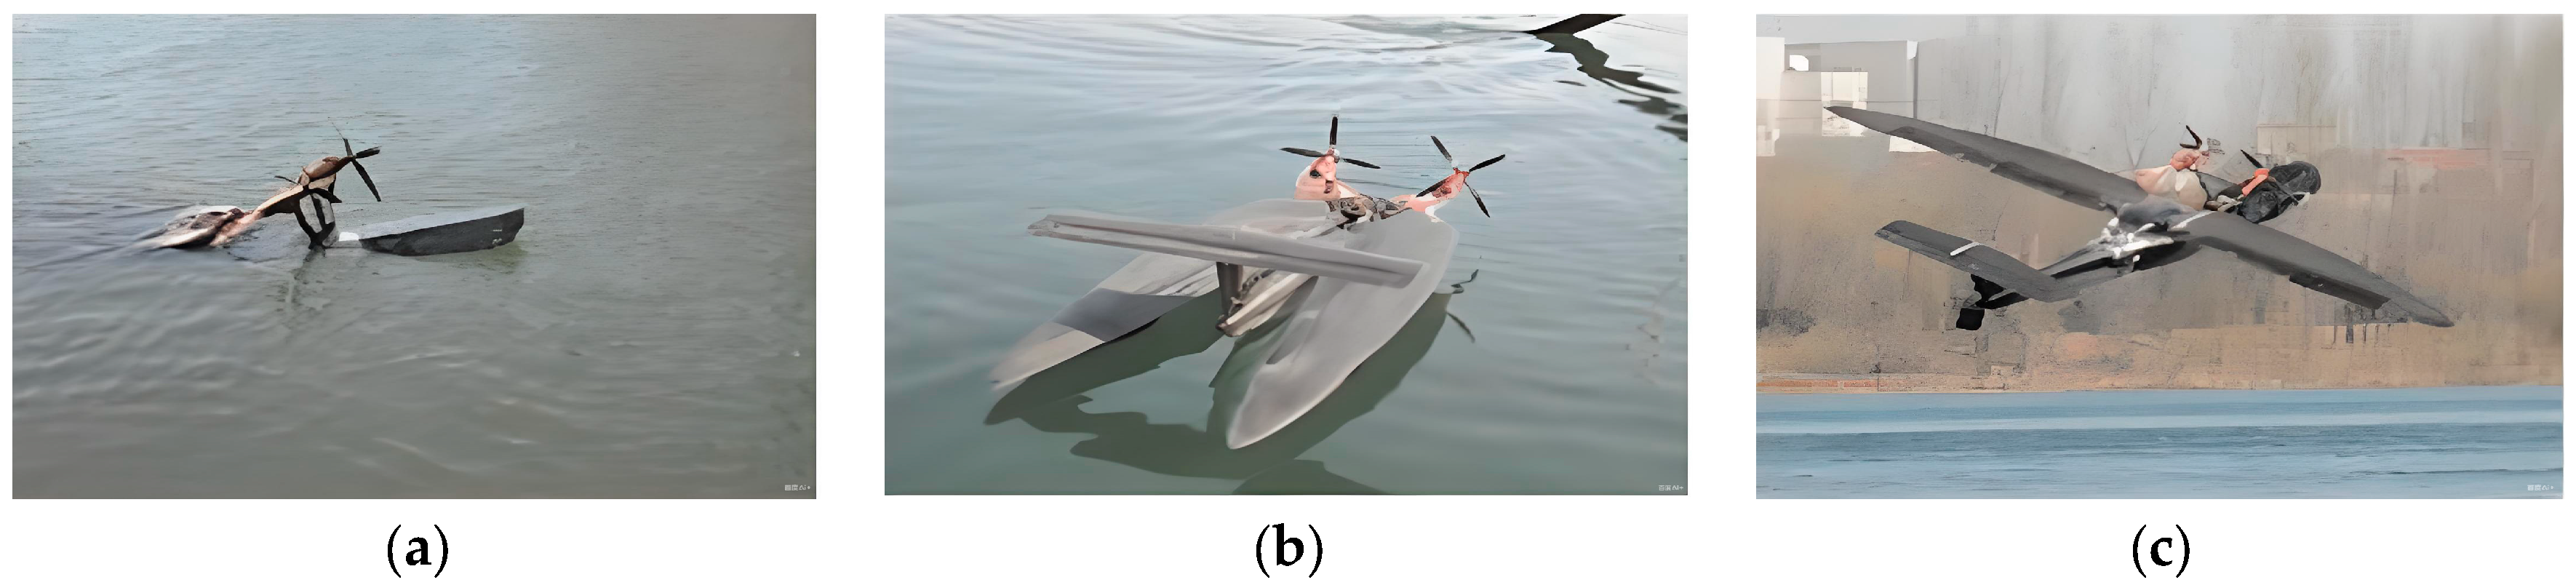
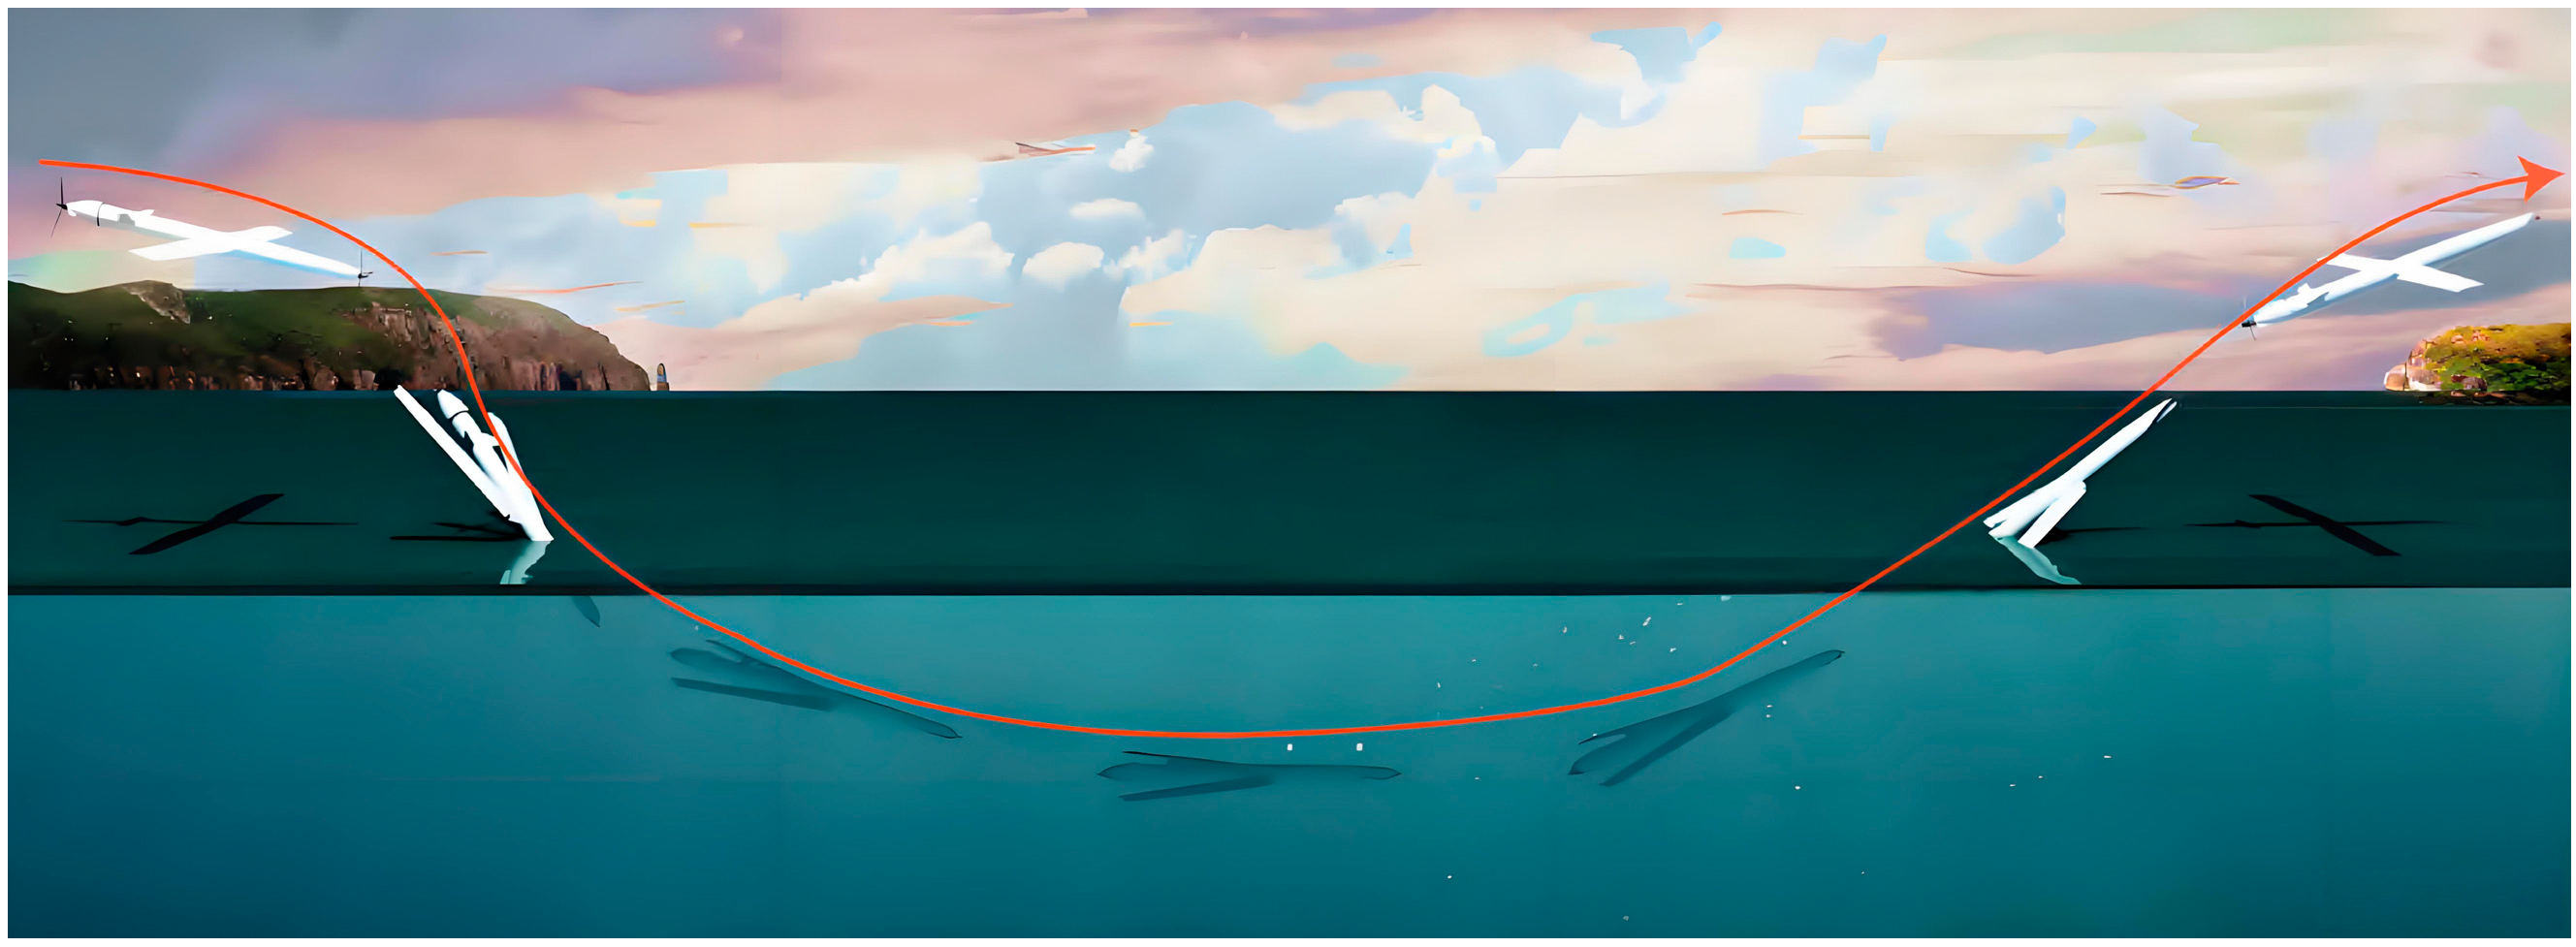
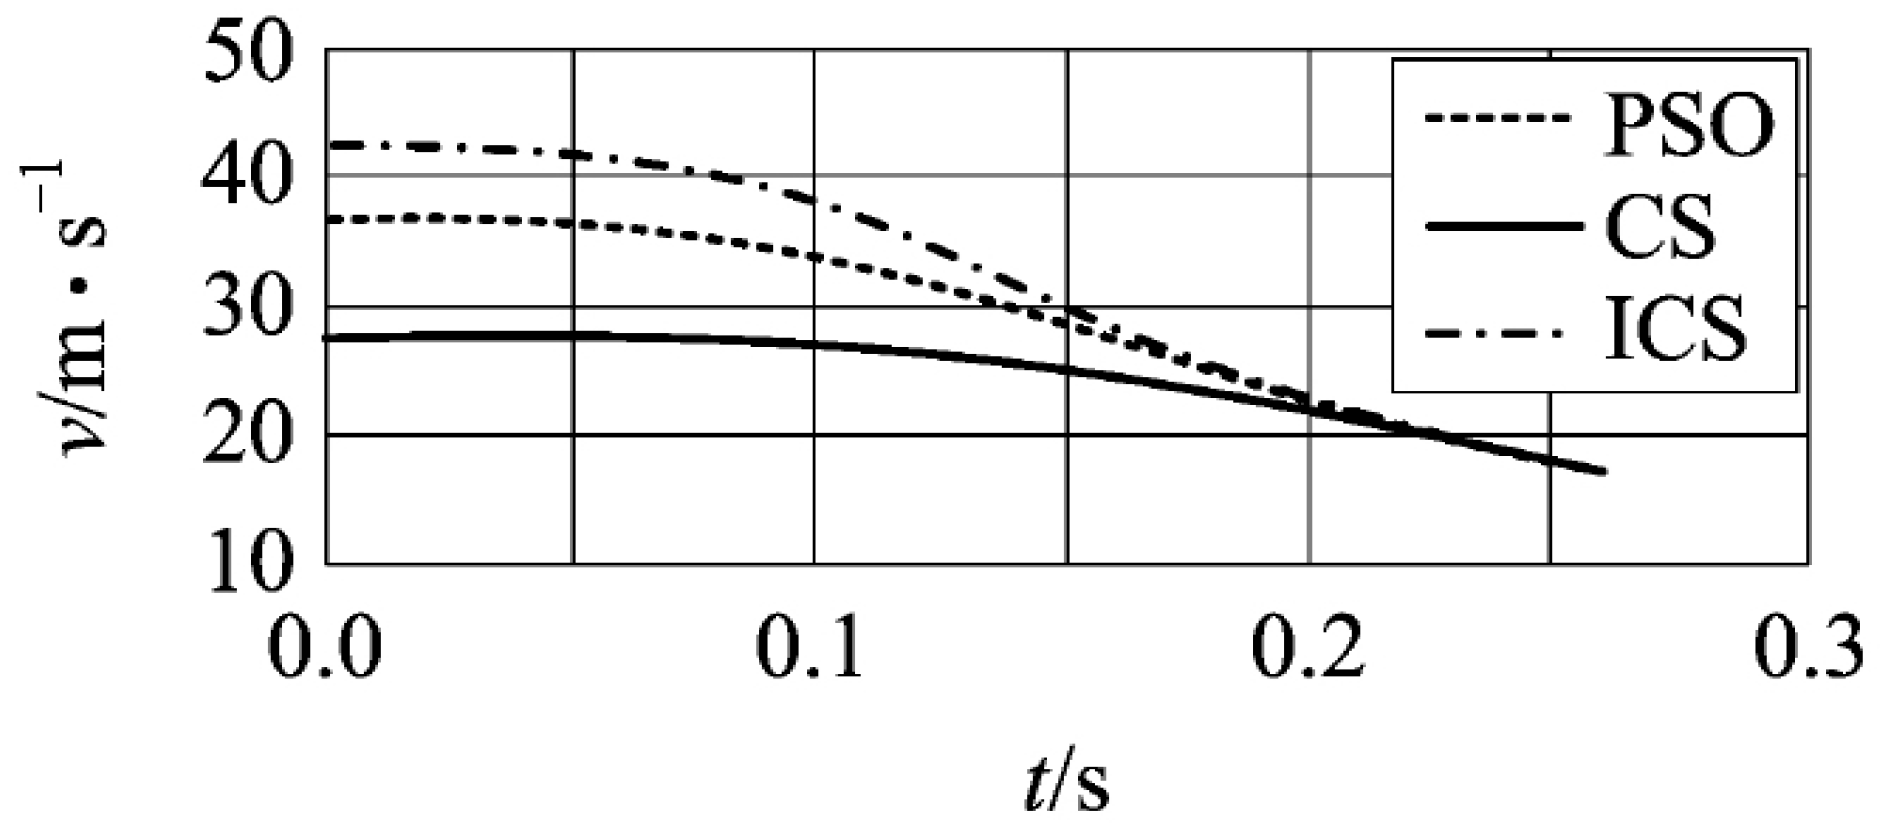
- Medium transition phase: Modeling the medium transition phase is particularly challenging due to the involvement of two-phase gas–liquid flow and free-surface effects (see Figure 17). Control strategies for cross-media motion must adapt to the differing dynamics in air, water, and transition phases. Conventional single-medium control laws prove insufficient, necessitating multi-mode adaptive control frameworks. During water entry or exit, rapid attitude adjustments are essential to mitigate impact loads. Wang proposed a segmented coupling model that divides the transition into three regions: the near-surface air domain, the gas–liquid mixing domain, and the near-bottom water domain. Each region employs distinct force models: the near-surface region accounts for aerodynamic forces and surface tension [60,61]. The mixing domain utilizes the VOF multiphase model to compute interfacial tension and cavitation-induced troops, and the near-bottom region considers only hydrodynamic forces. This approach accurately simulates variations in impact loads during water entry. At an entry velocity of 8 m/s, the deviation in peak impact acceleration is merely 3% compared to experimental data. In addition, Wang developed an adaptive control law employing fuzzy logic to identify the medium state and autonomously adjust control parameters. Attitude gain values are elevated to hasten response in the gas–liquid mixed domain and reduced to prevent overshoot in water. Experimental validation confirms that this method restricts attitude error during water entry to within 1° and reduces peak impact acceleration by 15% [62].
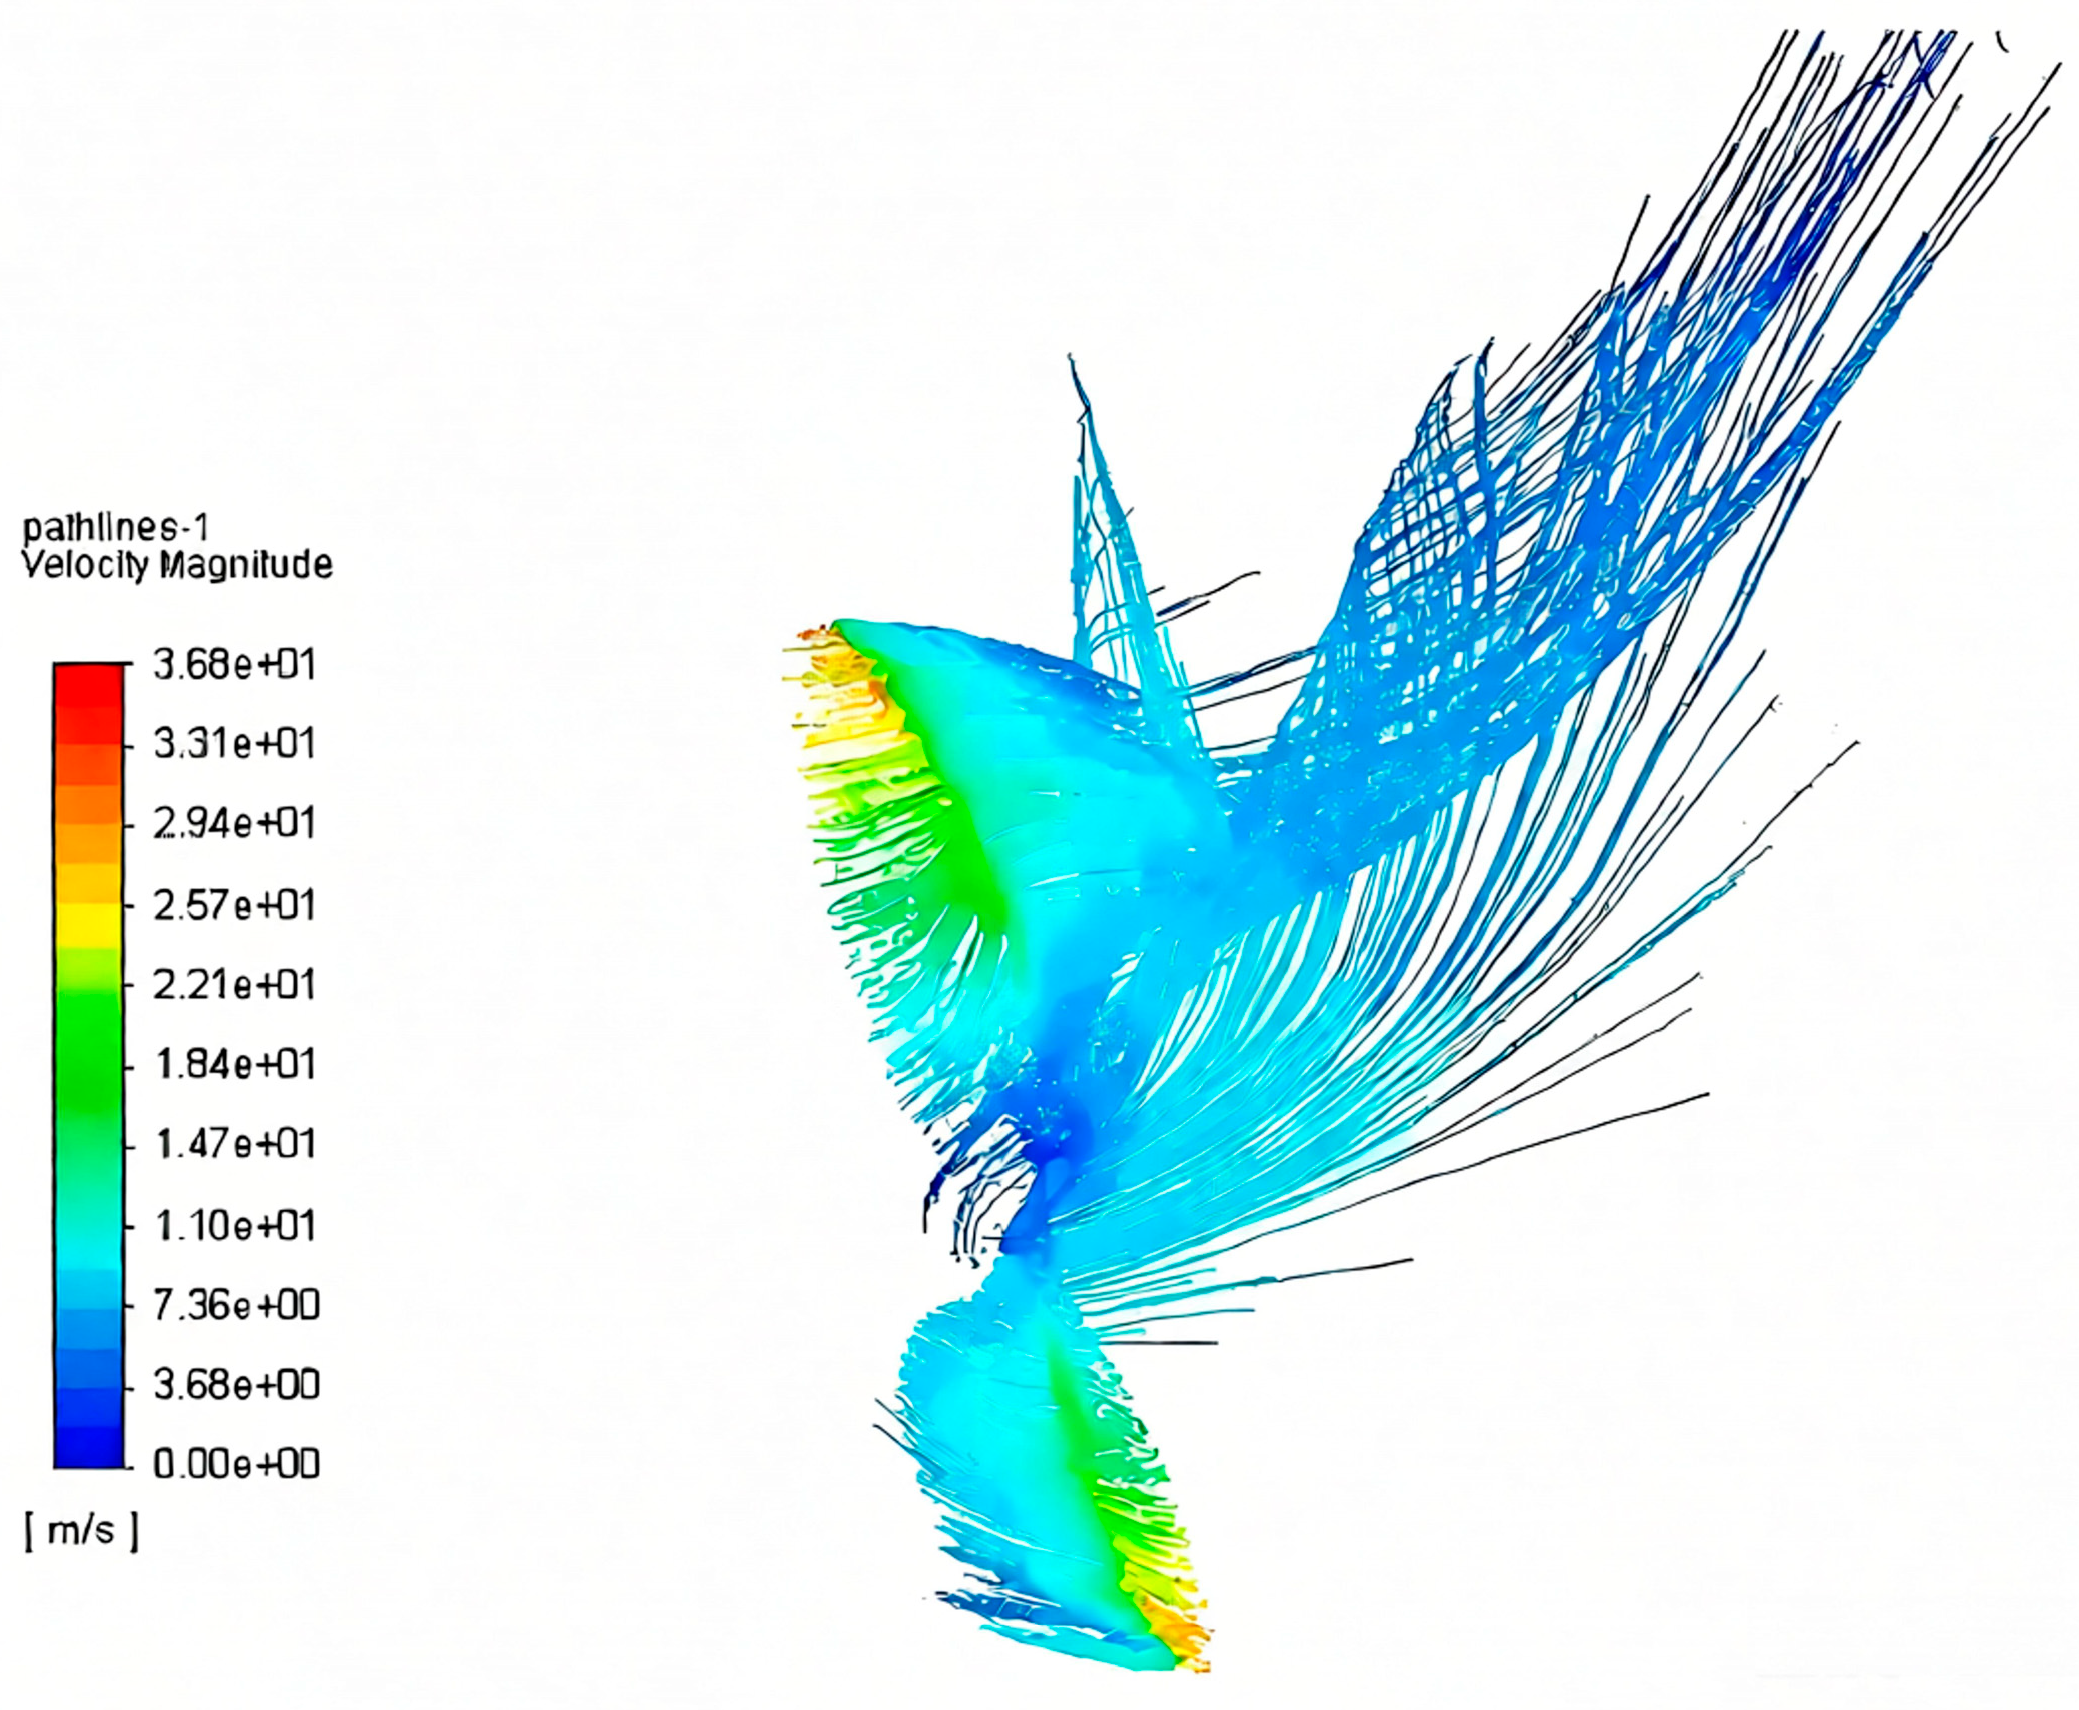
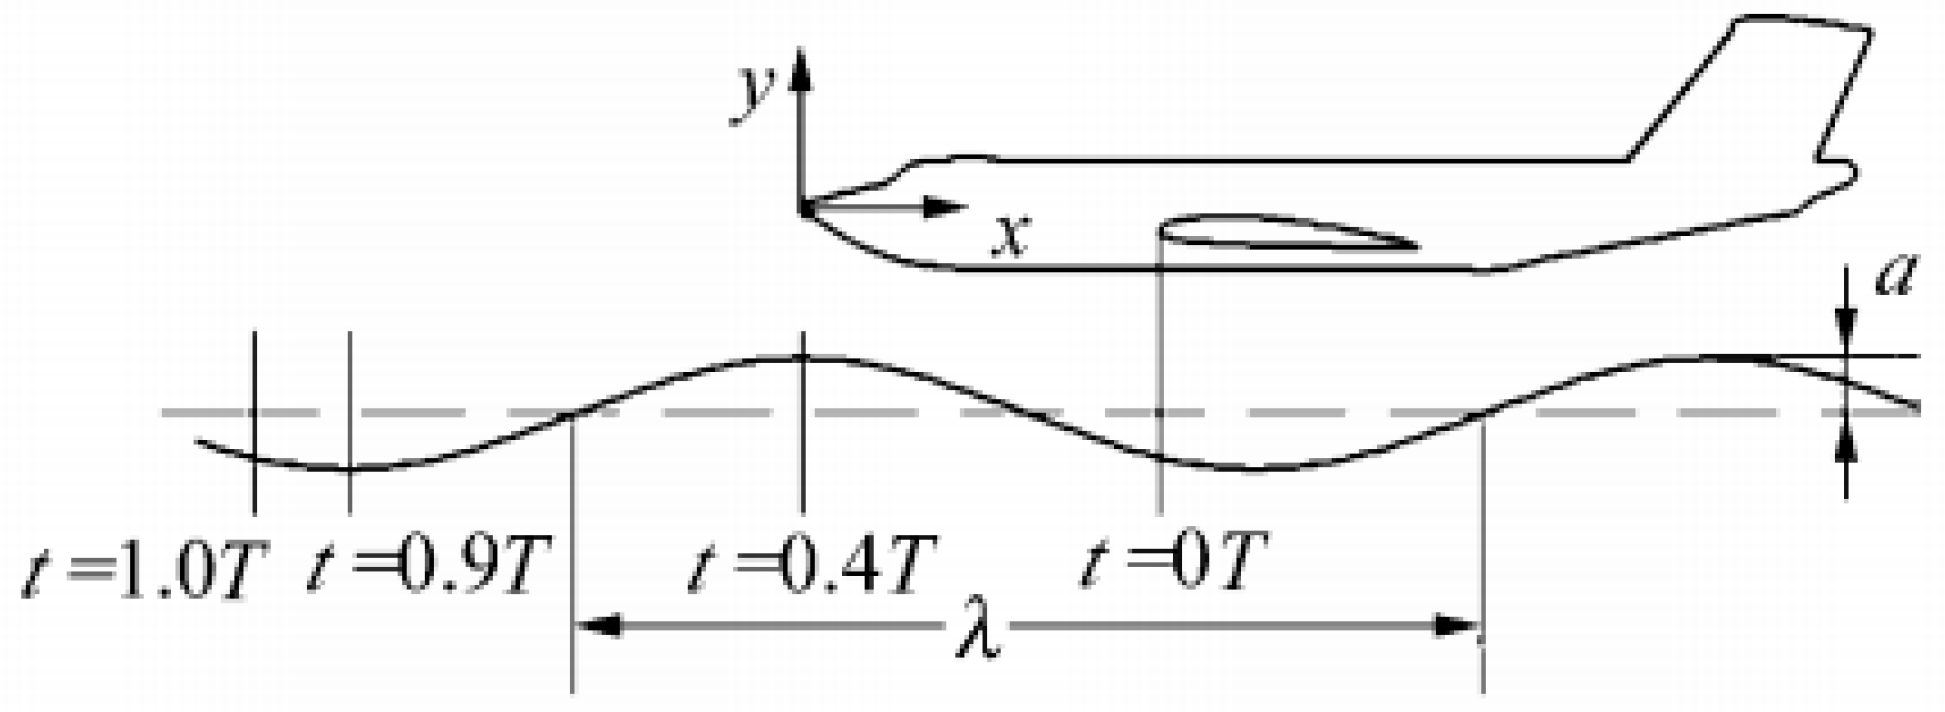
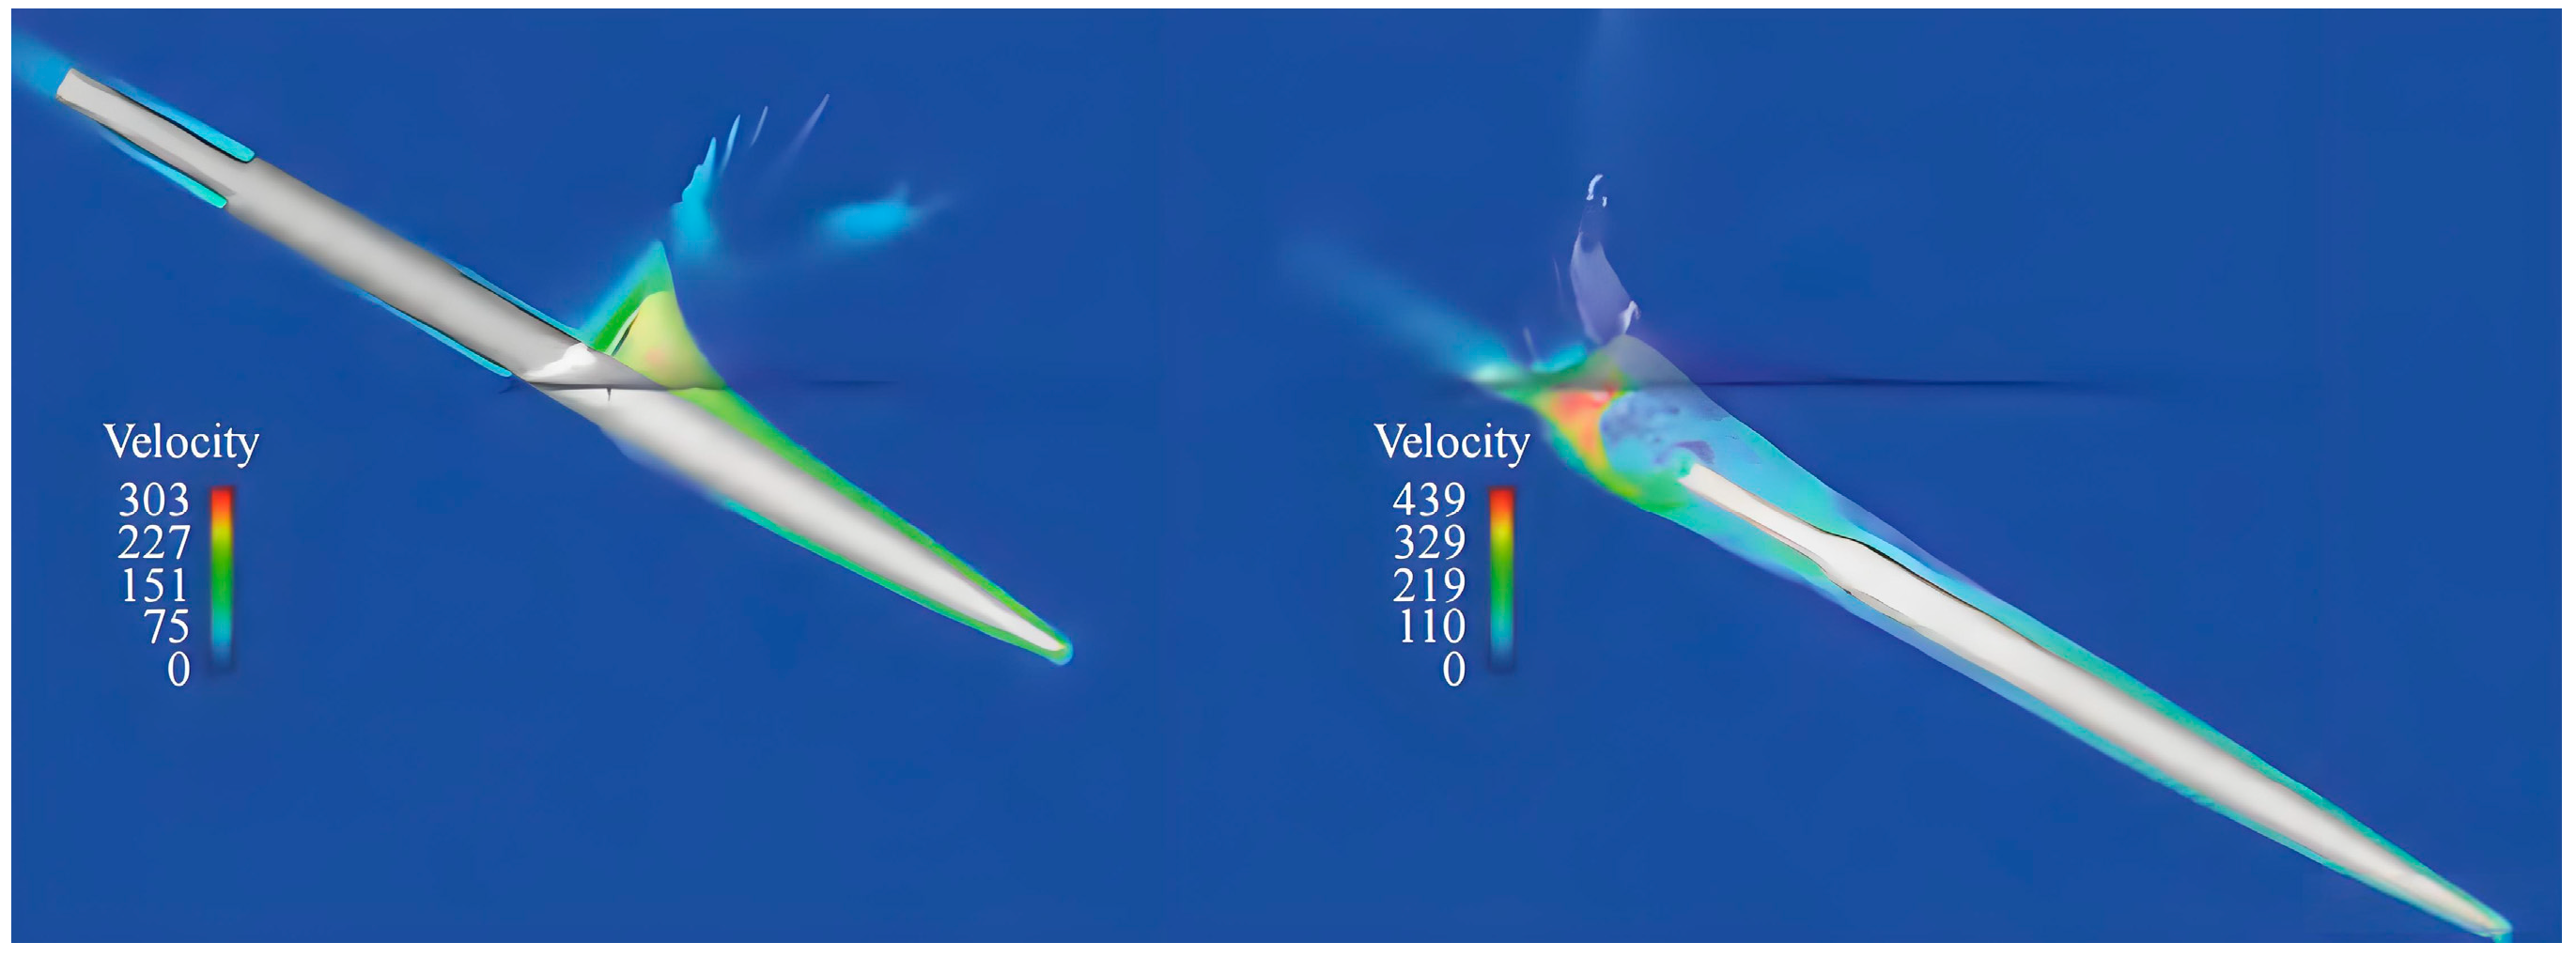
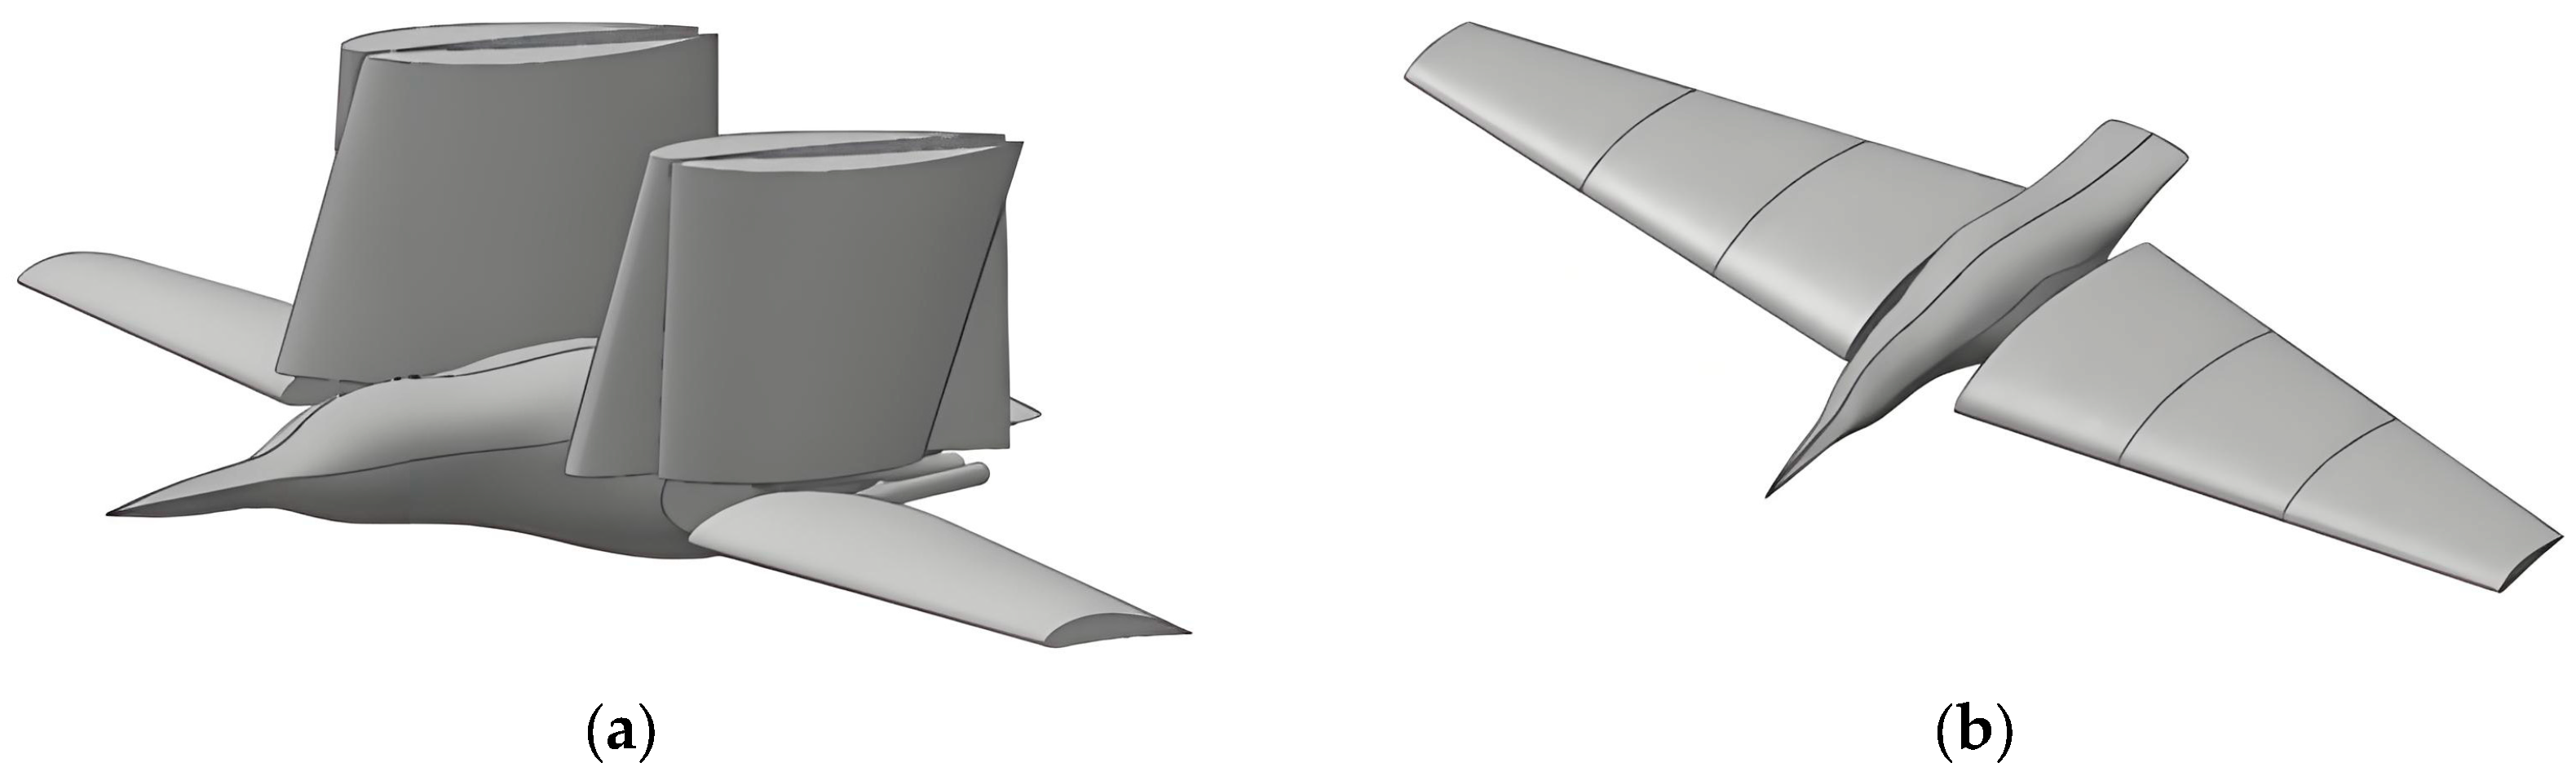
- Water Surface Effect: The Water Surface Effect significantly influences FUD operation during surface-level flight (see Figure 18 and Figure 19). This aerodynamic phenomenon occurs when downwash airflow is obstructed by the water surface, leading to increased pressure under the wing, enhanced lift, and reduced induced drag. Its effective altitude typically remains below half the wingspan. Although it improves the lift-to-drag ratio, it introduces challenges related to the coupling of multiphase flow. Wake-induced surface deformations—such as depression, splash, or penetration—can cause thrust fluctuations of 12–15% and pose risks of lift loss or stall. Numerical and experimental studies indicate that density and viscosity disparities between air and water, combined with environmental factors such as sea breezes, waves, and currents, result in an unsteady, periodically fluctuating mixed flow of air and water. This complicates the modeling and measurement of multiphase flows. Current models, including Cheeseman and PSM, exhibit limited accuracy in predicting near-surface behaviors. Future efforts should prioritize the development and validation of high-fidelity, coupled pneumatic-hydraulic models [64].

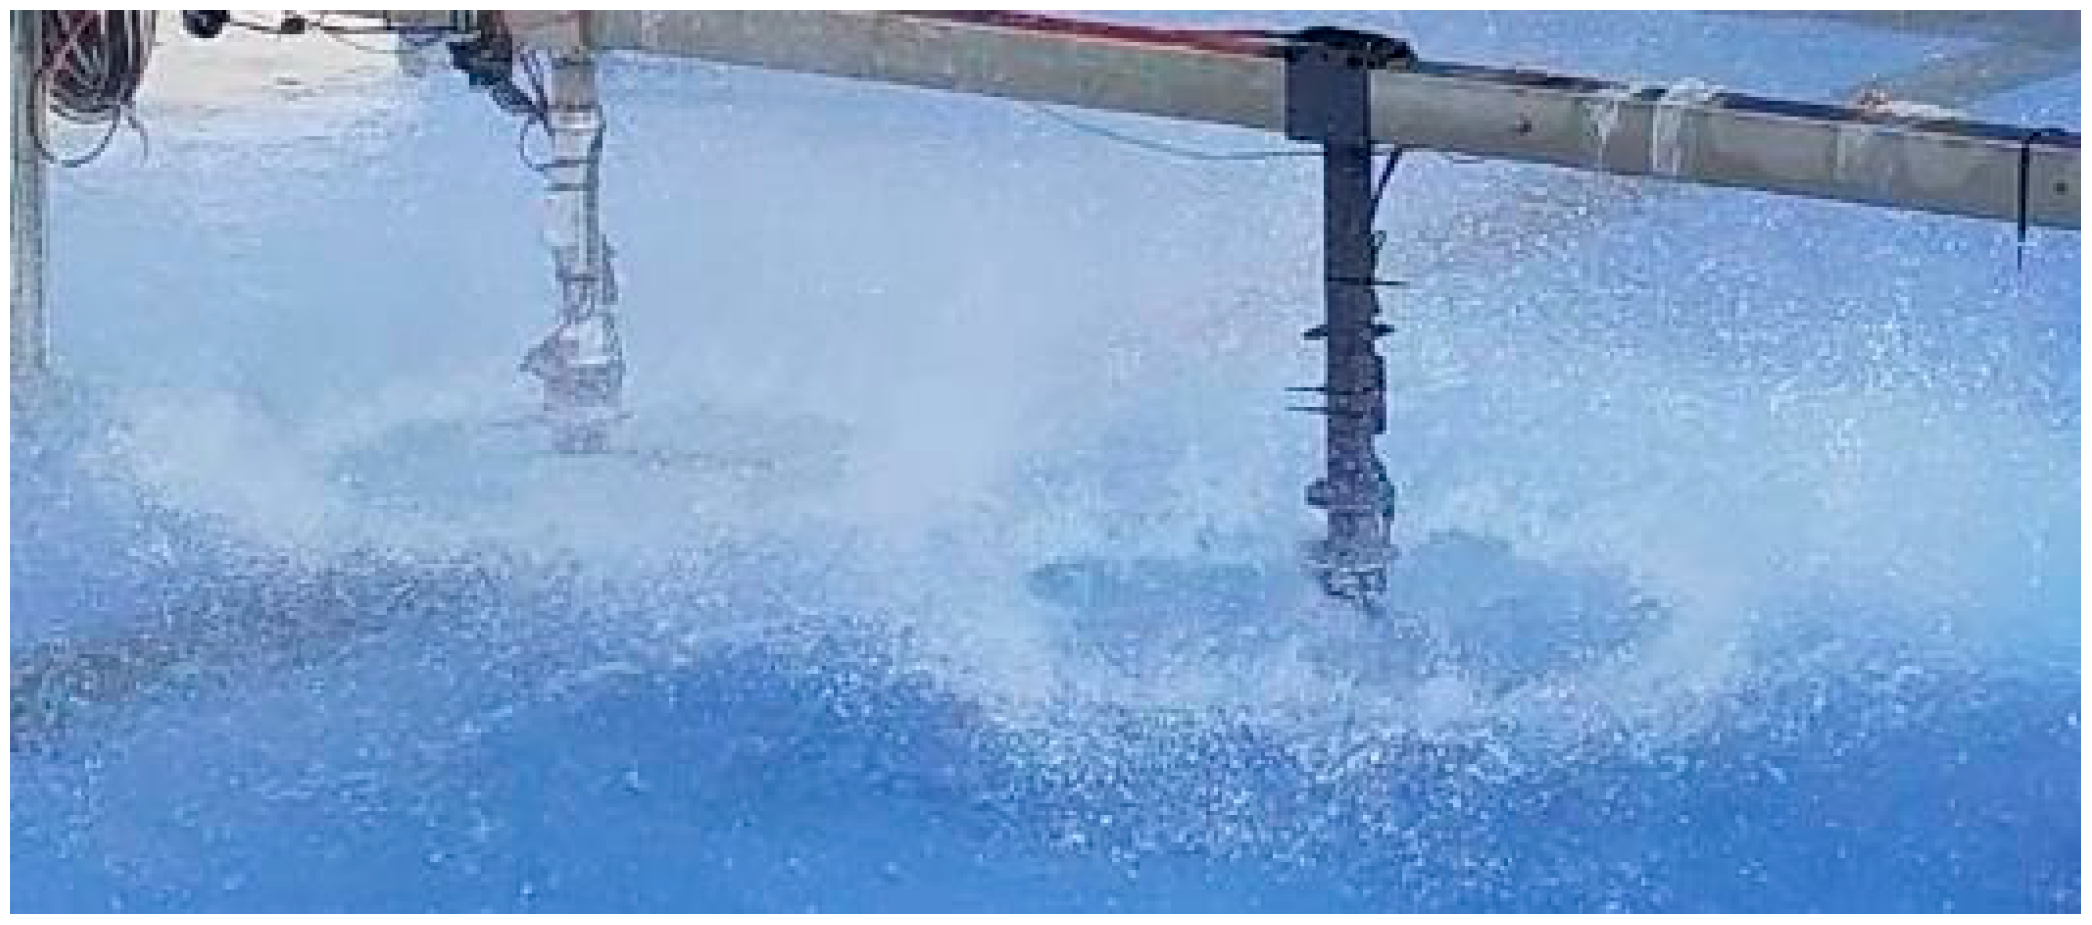
- Cavitation-bubble formation: At high-speed water entry or underwater, cavitation bubbles form when local water pressure falls below the saturated vapor pressure (see Figure 20). The emergence, evolution, and collapse of cavitation bubbles induce structural vibrations, increase impact loads, and may lead to material failure. Thus, FSI simulation represents a critical research focus. Du formulated a bidirectional coupled model for cavitation flow and structural vibration, targeting cavitation on elastic control surfaces of FUDs [67]. The fluid subsystem employs a full cavitation model to represent bubble dynamics, while the structural response is simulated via the finite element method. Simulations at a water-entry speed of 10 m/s revealed that cavitation collapse generates local pressures of up to 50 MPa, resulting in control surface deformations of 0.8 mm, which is consistent with experimental observations. To address interactions among multiple cavitation bubbles, Huang developed a multi-cavitation coupling model that considers pressure interference and flow-field superposition [68]. Simulations indicated that simultaneous cavitation at the nose and wingtips leads to bubble attraction and merging, amplifying collapse pressure by 20% compared to isolated cavitation. This insight guides anti-cavitation structural design, reinforcing high-risk regions such as the nose-wing junction with thicker titanium alloy plates. The coupling between cavitation, flow, and structure exacerbates attitude instability, underscoring the need for further optimization of impact-resistant designs and the development of cavitation suppression techniques.
4.2. Morphing-Flight Coordinated Control Technology
4.3. Strong Disturbance Control Algorithms
5. Experimental Verification Technology
5.1. Laboratory Testing Techniques
- Wind Tunnel Test: The airfoil of the “flyfish” was evaluated in a low-speed wind tunnel by Park at wind speeds ranging from 0 to 50 m/s [82]. They measured aerodynamic loads using a six-component balance and analyzed the surface flow field of the wing with PIV. The results indicated that the lift-to-drag ratio of the flyfish-inspired airfoil reached 12.5, which is 30% higher than that of the traditional NACA 0012 airfoil, thereby providing valuable data for wing design.
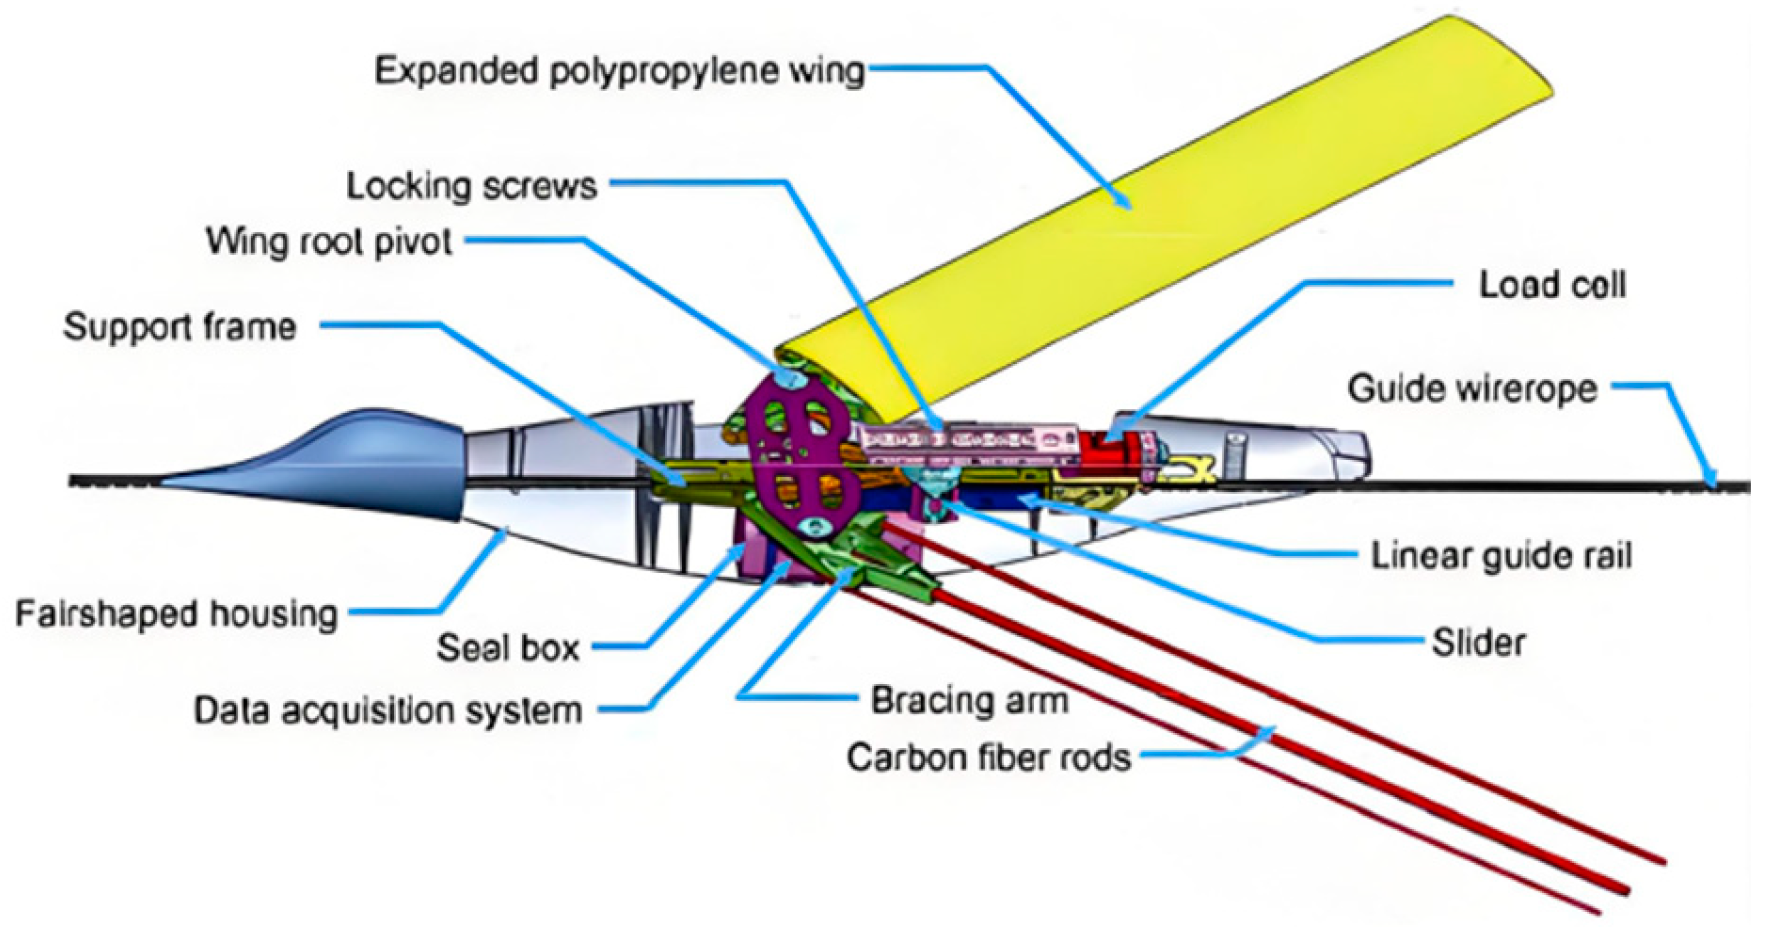
- Water Tunnel Test: The water tunnel tests were conducted to assess the hydrodynamic performance underwater, including resistance, propulsion efficiency, and cavitation characteristics. Lock evaluated the underwater propulsion capabilities in a circulating water tunnel, operating at flow rates of 0 to 10 m/s [83]. Strain sensors were employed to measure the hydrodynamics of the wing surface, offering insights for the design of propulsion systems. In 2022, Harbin Engineering University examined the cavitation characteristics of the Hybrid Autonomous Aerial Vehicle (FUD) in a cavitation water tunnel with pressures ranging from 0 to 0.5 MPa. By capturing images of cavitation bubble morphology with high-speed cameras, they discovered that cavitation bubbles began to form at the nose of the FUD when the underwater speed exceeded 4 m/s, thus providing a design benchmark for the maximum allowable underwater speed [84].
- Impact Bench Test: The impact bench test replicates the conditions of water entry impact and assesses the structural impact resistance. Beihang University performed a simulation of the water entry process for a bobby aircraft using a drop weight impact test bench with velocities ranging from 0 to 20 m/s. They recorded the impact load utilizing an acceleration sensor and assessed the structural stress through a strain gauge. The findings revealed that employing a gradient curvature design for the nose resulted in a 25% reduction in peak impact acceleration. Furthermore, the maximum stress within the structure was maintained at less than 60% of the material’s yield strength, confirming the efficacy of the impact-resistance design.
5.2. Lake/Sea Trial Technology
5.3. Cluster Collaborative Test
6. Application Scenarios and Development Trends of Folding-Wing FUD
6.1. Typical Application Scenarios
- Marine Resource Exploration: FUD is utilized for the exploration of deep-sea minerals, as well as oil and gas resources. It can transport payloads such as magnetometers and side-scan sonar, enabling it to cover extensive areas of ocean at high cruising speeds quickly. Once potential resource areas are identified, the process can seamlessly transition to submersible navigation, allowing for the measurement of resource parameters, including ore layer thickness and the reserves of oil and gas, at close range. Compared to traditional exploration vessels, FUD’s efficiency is ten times greater, while costs are reduced by 50%. Harbin Engineering University has adapted the “Longbow 2” into an exploration platform and has conducted oil and gas exploration trials in the South China Sea.
- Disaster Rescue: In the event of disasters such as typhoons, tsunamis, or shipwrecks, FUD can execute search and rescue operations. For example, it can navigate at low altitudes through affected areas and, upon identifying individuals in distress, enter the water for underwater navigation. Using sonar technology, it can pinpoint the locations of people in need and deploy lifesaving equipment, such as lifebuoys and emergency communication devices. Additionally, FUD can function as a communication relay, establishing an air-to-sea connection to link rescue workers with those affected. In 2023, during a rescue drill for a typhoon disaster in Fujian, Central South University successfully located three individuals in distress using FUD.
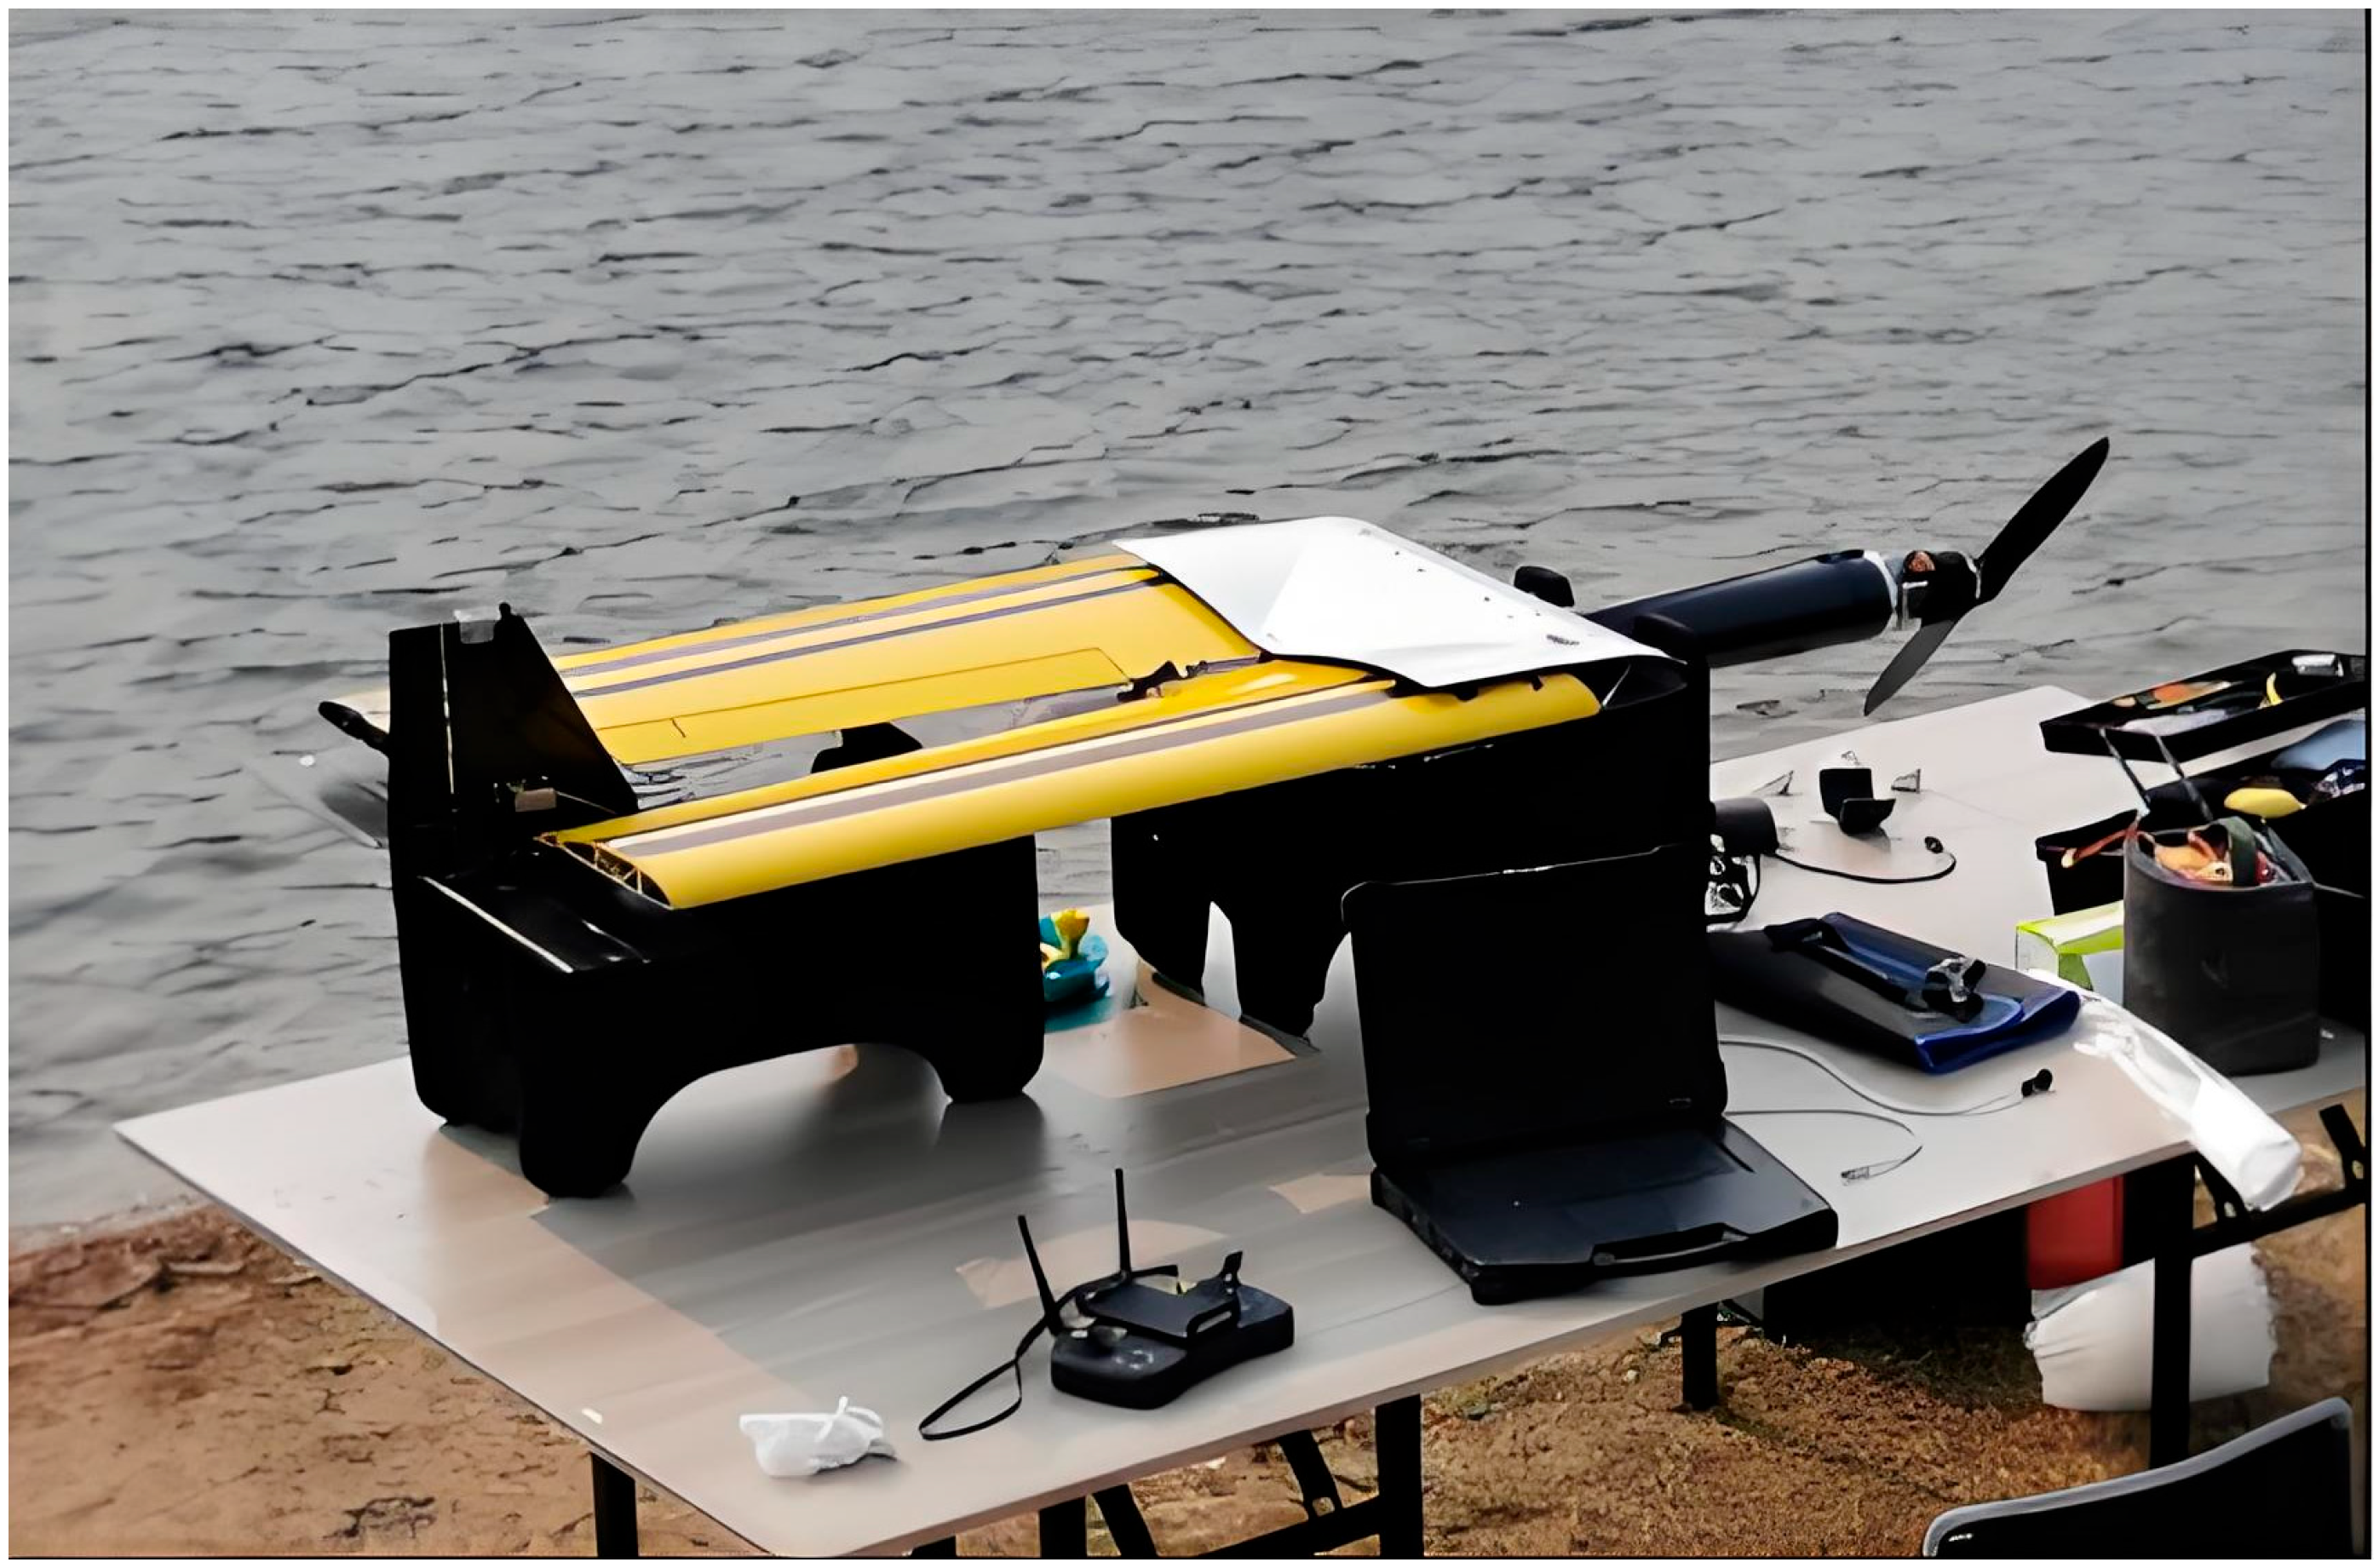
- Environmental Monitoring: FUD is also employed for monitoring environmental issues, including marine pollution and red tides (see Figure 24). It can carry payloads such as water quality sensors and spectrometers, allowing it to cruise through the air and assess the extent of pollution. Upon entering the water, it collects samples and analyzes the concentration of contaminants, such as oil and heavy metals, in real time, transmitting this data back to the ground station. The prototype of Beihang University’s “Flying Fish” has been utilized to monitor oil pollution in the Bohai Sea, achieving significantly broader coverage than traditional monitoring buoys.
6.2. Technological Development Trends
- Advanced Materials and Intelligent Morphing Structures: Future developments will focus on the synthesis of impact-resistant and anti-cavitation composite materials for critical components like the nose cone, while utilizing SMP for adaptive wing structures. The convergence of adaptive deformation technology, flexible material stiffness adjustment, and multimodal cooperative perception will enable the vehicle to reconfigure its shape in response to its surroundings autonomously. This capability will allow the dynamic optimization of deformation parameters, thereby maximizing aerodynamic lift during flight and minimizing hydrodynamic drag during underwater navigation [93].
- Cluster Collaboration and Intelligent Decision-Making: The introduction of deep learning algorithms, combined with advanced dynamic task allocation protocols, will significantly enhance the autonomous decision-making capabilities of FUDs in complex marine environments and adversarial scenarios. This intelligence will extend to robust multi-vehicle collaboration, improving resilience against jamming and enabling real-time, optimized task distribution within a cluster. Initiatives like the U.S. DARPA’s program, which aims to demonstrate autonomous decision-making for cross-media loitering munitions by 2026, underscore the strategic importance of this trend.
- Novel Propulsion and Energy Systems: To break the endurance bottleneck, innovations in power and propulsion are essential. Efforts will focus on enhancing energy density and optimizing the integration of air-water dual-purpose propulsion systems. A key breakthrough will be the development of multi-fuel compatible combustion chambers, capable of efficiently utilizing conventional aviation kerosene in the air and initiating reactions such as aluminum-water combustion underwater, thus reducing system complexity. Furthermore, energy harvesting technologies will be crucial. This includes deploying piezoelectric ceramics on the vehicle’s nose to convert water impact energy into electricity and integrating flexible piezoelectric films on wing surfaces to harvest energy from flow-induced vibrations. As evidenced by Beihang University’s plan to implement such energy recovery technologies in an upgraded “Flying Fish” prototype by 2026, which is projected to increase underwater endurance by 20%, these innovations are poised to extend mission durations significantly [94].
7. Conclusions and Prospects
Author Contributions
Funding
Data Availability Statement
DURC Statement
Conflicts of Interest
Abbreviations
| FUD | Flying Underwater Drone |
| ANN | Artificial Neural Network |
| ML | Machine Learning |
| CFD | Computational Fluid Dynamics |
| SMA | Shape Memory Alloy |
| CVT | Continuously Variable Transmission |
| VOF | Volume of Fluid |
| PI | Proportional-Integral |
| 6-DOF | Six-Degree-Of-Freedom |
| ADRC | Active Disturbance Rejection Control |
| ESO | Extended State Observer |
| LPV | Linear Parameter-Varying |
| SMC | Sliding Mode Control |
| RL | Reinforcement Learning |
| PIV | Particle Image Velocimetry |
| SMP | shape memory polymers |
| FSI | fluid–structure interaction |
| DARPA | Defense Advanced Research Projects Agency |
References
- Qi, H.; Hu, S.; Zhang, J.; Wu, G. Review of Hybrid Aerial Underwater Vehicle: Potential Applications in the Field of Underwater Marine Optics. Drones 2025, 9, 667. [Google Scholar] [CrossRef] [Scilit]
- Geder, J.D.; Ramamurti, R.; Edwards, D.; Sandberg, W.; Mueller, T. Swimming Performance of a Hybrid Unmanned Air-Underwater Vehicle. In Proceedings of the OCEANS 2016 MTS/IEEE Monterey, Monterey, CA, USA, 19–23 September 2016; pp. 1–5. [Google Scholar]
- Crouse, G. Conceptual Design of a Submersible Airplane. In Proceedings of the 48th AIAA Aerospace Sciences Meeting Including the New Horizons Forum and Aerospace Exposition, Orlando, FL, USA, 4–7 January 2010. [Google Scholar]
- Di Luca, M.; Mintchev, S.; Su, Y.X.; Shaw, E.; Breuer, K. A Bioinspired Separated Flow Wing Provides Turbulence Resilience and Aerodynamic Efficiency for Miniature Drones. Sci. Robot. 2020, 5, eaay8533. [Google Scholar] [CrossRef] [Scilit]
- Jiao, J.; Chen, C.; Wang, B.; Ying, P.; Wei, Q.; Nie, S. Active Flow Control Technology Based on Simple Droop Devices and a Co-Flow Jet for Lift Enhancement. Aerospace 2025, 12, 198. [Google Scholar] [CrossRef] [Scilit]
- Panta, A.; Marino, M.; Fisher, A.; Mohamed, A.; Watkins, S. Exploring the Impact of Rapidly Actuated Control Surfaces on Drone Aerodynamics. Drones 2023, 7, 494. [Google Scholar] [CrossRef] [Scilit]
- Abdolahipour, S. Review on Flow Separation Control: Effects of Excitation Frequency and Momentum Coefficient. Front. Mech. Eng. 2024, 10, 1380675. [Google Scholar] [CrossRef] [Scilit]
- Ramamurti, R.; Geder, J.D.; Edwards, D.; Palmisano, J.; Sandberg, W.C.; Nadira, A. Computational Studies for the Development of a Hybrid UAV/UUV. In Proceedings of the 33rd AIAA Applied Aerodynamics Conference, Dallas, TX, USA, 22–26 June 2015; p. 2414. [Google Scholar]
- Mathaiyan, V.; Vijayanandh, R.; Senthil, K.; Ramesh, M. Conceptual Design and Numerical Analysis of an Unmanned Amphibious Vehicle. In Proceedings of the AIAA Scitech 2021 Forum, Virtual Event, 11–15, 19–21 January 2021; p. AIAA 2021-1285. [Google Scholar]
- Paulo, L.J.; Armando, A.; Mario, F.M. A Survey on Aerial Submersible Vehicles. In Proceedings of the IEEE/OES Oceans, Bremen, Germany, 11–14 May 2009; pp. 1–7. [Google Scholar]
- Trdnt, Y.; Jason, G.; Dan, E. Flimmer: A Flying Submarine; Naval Research Laboratory SPECTRA: Washington, DC, USA, 2015. [Google Scholar]
- Petrov, G. Flying Submarine. Fleet 1995, 3, 52–53. [Google Scholar]
- Yao, G.C.; Li, Y.Z.; Zhang, H.Y.; Wang, T.M.; Liang, J.H. Review of Hybrid Aquatic-Aerial Vehicle (HAAV): Classifications, Current Status, Applications, Challenges and Technology Perspectives. Prog. Aerosp. Sci. 2023, 139, 100902. [Google Scholar] [CrossRef] [Scilit]
- Feng, J.F.; Hu, J.H.; Qi, D. Development Requirements and Key Technologies of Water-Air Cross-Domain Vehicles. J. Air Force Eng. Univ. Nat. Sci. Ed. 2019, 20, 8–13. (In Chinese) [Google Scholar]
- Zhang, C.Y.; Yang, F.; Liu, K.; Wang, J.H.; Li, W. Development and Key Technology Analysis of Reconfigurable Cross-Domain Aircraft. Astron. Syst. Eng. Technol. 2021, 5, 54–61, 72. (In Chinese) [Google Scholar]
- Yang, Y.X.; Duan, Y.J.; Huang, L.K.; Li, J.; Wang, Z.T. Development Concept of Combined Power Technology for Air/Water Cross-Domain Equipment. J. Propuls. Technol. 2020, 41, 2237–2244. (In Chinese) [Google Scholar]
- Hou, T.G.; Jin, D.Z.; Gong, Y.D.; Wang, J.H.; Li, Y. Advances in Frontier Technologies of Water-Air Cross-Domain Vehicles. Sci. Technol. Rev. 2023, 41, 5–22. (In Chinese) [Google Scholar]
- Li, C.; Lyu, R.Y.; Qian, R.J.; Li, Z.Y.; Wang, Z. Research on the Development and Application of U.S. Cross-Domain Vehicle Technology. Tactical Missile Technol. 2023, 6, 120–127. (In Chinese) [Google Scholar]
- Margulis, M.; Blaise, P.; Stimpson, S.; Graham, A.; Collins, B. Development of a Coupled Subplane Capability in Mpact. EPJ Web Conf. 2021, 247, 06051. [Google Scholar] [CrossRef] [Scilit]
- Liu, X.; Dou, M.; Huang, D.; Gao, S.; Yan, R.; Wang, B.; Cui, J.; Ren, Q.; Dou, L.; Gao, Z.; et al. TJ-FlyingFish: Design and Implementation of an Aerial-Aquatic Quadrotor with Tiltable Propulsion Units. In Proceedings of the 2023 IEEE International Conference on Robotics and Automation (ICRA), London, UK, 29 May–2 June 2023; pp. 7324–7330. [Google Scholar] [CrossRef] [Scilit]
- Liu, X.; Dou, M.; Yan, R.; Huang, D.; Gao, S.; Wang, B.; Cui, J.; Ren, Q.; Dou, L.; Gao, Z.; et al. TJ-FlyingFish: An Unmanned Morphable Aerial–Aquatic Vehicle System. Unmanned Syst. 2024, 12, 409–428. [Google Scholar] [CrossRef] [Scilit]
- Liu, K.; Xiao, J.; Lin, H.; Cao, Y.; Peng, H.; Huang, K.; Lu, H. SurfAAV: Design and Implementation of a Novel Multimodal Surfing Aquatic-Aerial Vehicle. J. Field Robot. 2025, 39, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Lyu, C.; Lu, D.; Xiong, C.; Hu, R.; Jin, Y.; Wang, J.; Zeng, Z.; Lian, L. Toward a Gliding Hybrid Aerial Underwater Vehicle: Design, Fabrication, and Experiments. J. Field Robot. 2022, 39, 543–556. [Google Scholar] [CrossRef] [Scilit]
- Moore, J.; Fein, A.; Setzler, W. Design and Analysis of a Fixed-Wing Unmanned Aerial-Aquatic Vehicle. In Proceedings of the 2018 IEEE International Conference on Robotics and Automation (ICRA), Brisbane, Australia, 21–25 May 2018; pp. 1236–1243. [Google Scholar]
- Weisshaar, T.A. Morphing Aircraft Systems: Historical Perspectives and Future Challenges. J. Aircr. 2013, 50, 337–353. [Google Scholar] [CrossRef] [Scilit]
- Erbil, M.A.; Prior, S.D.; Karamanoglu, M.; Knight, G. Reconfigurable Unmanned Aerial Vehicles. In Proceedings of the International Conference on Manufacturing and Engineering Systems, Istanbul, Turkey, 16–18 December 2009; pp. 392–396. [Google Scholar]
- Yang, X.B.; Liang, J.H.; Wen, L.; Wang, T.M. Research Status of Water-Air Amphibious Cross-Domain Unmanned Aerial Vehicles. Robot 2018, 40, 102–114. (In Chinese) [Google Scholar] [CrossRef]
- Müller, R.; Abaid, N.; Boreyko, J.B.; Fowlkes, C.; Gardner, A.; Gorb, S.; Kim, S.; Kovač, M.; Lee, S.H.; López, R.; et al. Biodiversifying Bioinspiration. Bioinspir. Biomim. 2018, 13, 053001. [Google Scholar] [CrossRef] [Scilit]
- Davenport, J. How and Why Do Flying Fish Fly? Rev. Fish Biol. Fish. 1994, 4, 184–214. [Google Scholar] [CrossRef] [Scilit]
- Deng, J.; Zhang, L.X.; Liu, Z.Y.; Liu, Y.G.; Wu, Z. Numerical Prediction of Aerodynamic Performance for a Flying Fish during Gliding Flight. Bioinspir. Biomim. 2019, 14, 046009. [Google Scholar] [CrossRef] [Scilit]
- Hu, J.H.; Xu, B.W.; Feng, J.F.; Qi, D. Research on Water-Exit and Take-Off Process for Morphing Unmanned Submersible Aerial Vehicle. China Ocean Eng. 2017, 31, 202–209. [Google Scholar] [CrossRef] [Scilit]
- Huang, X.T.; Sun, P.N.; Zhang, A.M. Water Entry Problems Simulated by an Axisymmetric SPH Model with VAS Scheme. J. Mar. Sci. Appl. 2022, 21, 1–15. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.B.; Wang, T.M.; Liang, J.H.; Yao, G.C.; Li, Y.M. Numerical Analysis of Biomimetic Gannet Impacting with Water during Plunge-Diving. In Proceedings of the 2012 IEEE International Conference on Robotics and Biomimetics (ROBIO), Guangzhou, China, 11–14 December 2012; pp. 569–574. [Google Scholar]
- Liu, H.X. Research on the Mechanism of Bionic Cross-Media Vehicle and Prototype Engineering. Ph.D. Thesis, Beihang University, Beijing, China, 2009. (In Chinese) [Google Scholar]
- Fabian, A.; Feng, Y.F.; Swartz, E.; Ratti, J.; Tricaud, C.; Baillieul, J.; Sabet, S. Hybrid Aerial Underwater Vehicle; MIT Lincoln Lab: Lexington, MA, USA, 2012. [Google Scholar]
- Liang, J.H.; Yang, X.B.; Wang, T.M.; Yao, G.C.; Li, Y.M. Design and Experiment of a Bionic Gannet for Plunge-Diving. J. Bionic Eng. 2013, 10, 282–291. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.B.; Wang, T.M.; Liang, J.H.; Yao, G.C.; Li, Y.M. Submersible Unmanned Aerial Vehicle Concept Design Study. In Proceedings of the AIAA Aviation Technology, Integration, and Operations Conference, Los Angeles, CA, USA, 12–14 August 2013; p. 4422. [Google Scholar]
- Siddall, R.; Kovač, M. Fast Aquatic Escape with a Jet Thruster. IEEE/ASME Trans. Mechatron. 2017, 22, 217–226. [Google Scholar] [CrossRef] [Scilit]
- Armanini, S.F.; Siddall, R.; Kovac, M. Modelling and Simulation of a Bioinspired Aquatic Micro Aerial Vehicle. In Proceedings of the AIAA Aviation 2019 Forum, Dallas, TX, USA, 17–21 June 2019; p. 3115. [Google Scholar]
- Wang, B.X. Research on Motion Control of a Folding-Wing Cross-Domain Vehicle. Master’s Thesis, Harbin Engineering University, Harbin, China, 2024. (In Chinese) [Google Scholar] [CrossRef]
- Zhu, S. The Design and Research of Power System in Water-Air UAV. Master’s Thesis, Nanchang Hangkong University, Nanchang, China, 2012. (In Chinese) [Google Scholar]
- Yun, Z.; Chen, L.; Luo, Z.R.; Shang, J.Z. Numerical Simulation of Fluid Dynamics of Variable-Sweep Wing of Cross-Media Vehicle Based on Sarrus Mechanism. J. Mach. Des. 2019, 36, 15–20. (In Chinese) [Google Scholar]
- Tan, Y.H.; Chen, B.M. Design of a Morphable Multirotor Aerial-Aquatic Vehicle. In Proceedings of the OCEANS 2019 MTS/IEEE Marseille, Marseille, France, 17–20 June 2019; pp. 1–8. [Google Scholar]
- Shan, R.L. Research on Optimization Design and Experimental Method of Water-Air Dual-Purpose Propeller. Master’s Thesis, Shanghai Jiao Tong University, Shanghai, China, 2021. (In Chinese) [Google Scholar] [CrossRef]
- Li, P.F.; Huang, L.Y.; Xia, Z.X.; Liu, Y.; Tian, A. Research on the Working Characteristics of a Boron-Based Fuel-Rich Propellant Cross-Domain Ramjet. J. Solid Rocket Technol. 2022, 45, 662–667. (In Chinese) [Google Scholar]
- Schneider, S.J. Hydrogen Peroxide-Water-Ethanol Monopropellant Blend for CubeSat Propulsion. In Proceedings of the AIAA Propulsion and Energy 2020 Forum, Virtual Event, 24–28 August 2020; p. 3809. [Google Scholar]
- Zufferey, R.; Ancel, A.O.; Farinha, A.; Siddall, R.; Armanini, S.F.; Mange, R.; Stewart, W.J.; Kovac, M. Consecutive Aquatic Jump-Gliding with Water-Reactive Fuel. Sci. Robot. 2019, 4, eaax7330. [Google Scholar] [CrossRef] [Scilit]
- Wu, J.M.; Yang, Y.X.; Wang, Z.T.; Li, J.; Zhang, H. Research Status and Prospects of Propellant Feeding for Powder Engines. J. Aerosp. Power 2024, 39, 219–228. (In Chinese) [Google Scholar]
- Liu, P.A.; Chang, H.; Li, S.S.; Wang, J.; Zhang, L. Numerical Simulation of Distributed Combustion of the Aluminized Composite Propellant. J. Solid Rocket Technol. 2018, 41, 156–161, 168. (In Chinese) [Google Scholar]
- Whitmore, S.A.; Merkley, D.P. Arc-Ignition of a 70%–85% Hydrogen Peroxide/ABS Hybrid Rocket System. In Proceedings of the 53rd AIAA/SAE/ASEE Joint Propulsion Conference, Atlanta, GA, USA, 10–12 July 2017; p. 5047. [Google Scholar]
- Chen, W.W.; Huang, L.Y.; Xia, Z.X.; Liu, Y.; Tian, A. Theoretical Performance and Working Parameters Analysis of Trans-Medium Ramjet. Acta Aeronaut. Astronaut. Sin. 2020, 41, 197–206. (In Chinese) [Google Scholar]
- Yang, X.B.; Pei, X. Hybrid System for Powering Unmanned Aerial Vehicles: Demonstration and Study Cases. In Hybrid Technologies for Power Generation; Academic Press: Cambridge, MA, USA; Elsevier: Amsterdam, The Netherlands, 2022; pp. 439–473. [Google Scholar]
- Rendón, M.A.; Josselyn, G.M.; Smith, H.; Jones, P. Aircraft Hybrid-Electric Propulsion: Development Trends, Challenges and Opportunities. J. Control Autom. Electr. Syst. 2021, 32, 1244–1268. [Google Scholar] [CrossRef] [Scilit]
- Cong, M. Cormorant Submarine-Launched Multi-Purpose UAV Completes Splashdown and Recovery Test. Winged Missile J. Feihang Daodan 2007, 5, 25–26. (In Chinese) [Google Scholar]
- Stewart, W.; Weisler, W.; MacLeod, M.; Anderson, M.B.; DeVries, L.; Epps, B.; Lentink, D. Design and Demonstration of a Seabird-Inspired Fixed-Wing Hybrid UAV-UUV System. Bioinspir. Biomim. 2018, 13, 056013. [Google Scholar] [CrossRef] [Scilit]
- Siddall, R.; Kovač, M. Launching the AquaMAV: Bioinspired Design for Aerial–Aquatic Robotic Platforms. Bioinspir. Biomim. 2014, 9, 031001. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Siddall, R.; Kovač, M. A Water Jet Thruster for an Aquatic Micro Air Vehicle. In Proceedings of the 2015 IEEE International Conference on Robotics and Automation (ICRA), Seattle, WA, USA, 26–30 May 2015; pp. 3979–3985. [Google Scholar]
- Tang, Y.L.; Li, S.P.; Liu, Z.; Wang, Y.; He, B. Thrust Characteristics of Underwater Solid Rocket Motors. J. Aerosp. Power 2017, 32, 477–485. (In Chinese) [Google Scholar]
- Tang, S.J.; Zhang, B.C.; Yue, C.H.; Guo, J.J. Analysis of Key Technologies and Research Trends of Flight Dynamics for Cross-Domain Vehicles. Winged Missile J. Feihang Daodan 2011, 6, 7–13. (In Chinese) [Google Scholar]
- Wang, C.; Xu, H.Y.; Ma, G.H.; Li, H.Y.; Yan, J.Y. Research Progress on Frontier Technologies of Dynamics for Cross-Domain Vehicles. J. Unmanned Undersea Syst. 2024, 32, 384–395. (In Chinese) [Google Scholar]
- Wang, C.; Xu, H.Y.; Lu, J.X. Research Status and Prospects of Multiphase Flow Field and Motion Characteristics during Water Entry of Cross-Domain Vehicles. J. Unmanned Undersea Syst. 2023, 31, 38–49. (In Chinese) [Google Scholar]
- Siddall, R.; Kennedy, G.; Kovac, M. High-Power Propulsion Strategies for Aquatic Take-Off in Robotics. In Springer Proceedings in Advanced Robotics; Springer: Cham, Switzerland, 2017; Volume 3, pp. 5–20. [Google Scholar]
- Liu, Y.; Wu, Z.L.; Tan, H.J. Related Technologies and Analysis of Cross-Domain Aircraft. Aviat. Power 2024, 2, 13–16. (In Chinese) [Google Scholar]
- Bang, C.S.; Rana, Z.A.; Könözsy, L.; Marchante Rodriguez, V.; Temple, C. Numerical Investigation and Fluid-Structure Interaction (FSI) Analysis on a Double-Element Simplified Formula One (F1) Composite Wing in the Presence of Ground Effect. Fluids 2022, 7, 85. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Bai, X.Z.; Zhang, D.X.; Lin, Z.C.; Fan, Z.L.; Wu, W.H. Experimental Research on the Aerodynamic Characteristics of the Near-Water Effect of Multi-Rotor. Acta Aeronaut. Astronaut. Sin. 2025, 46, 32234. (In Chinese) [Google Scholar] [CrossRef]
- Qu, Q.L.; Liu, P.Q.; Qin, X.G. Numerical Research on Aerodynamic Characteristics of WIG Craft Flying over Wavy Ground. Acta Aeronaut. Astronaut. Sin. 2007, 28, 1327–1333. (In Chinese) [Google Scholar]
- Du, T.Z.; Huang, R.F.; Wang, C. Simulation Analysis of Fluid-Structure Interaction for Cavitating Flow Around Elastic Rudder Wings of Cross-Domain Vehicles. Astron. Syst. Eng. Technol. 2020, 4, 28–33. (In Chinese) [Google Scholar]
- Huang, Z.G.; Fan, H.W.; Chen, Z.H.; Hou, Y.; Li, J. Numerical Simulation Study on the Mechanism and Characteristics of High-Speed Water Entry of Hollow Projectile. Explos. Shock Waves 2024, 44, 117–131. (In Chinese) [Google Scholar]
- Ming, F.R.; Wang, J.J.; Liu, W.T.; Liu, X.J.; Zhang, A.M. Review of Multiphase Flow and Fluid-Structure Interaction of High-Speed Water Entry. Acta Aerodyn. Sin. 2024, 42, 68–85. (In Chinese) [Google Scholar] [CrossRef]
- Guo, T.H.; Hou, Z.X.; Zhu, B.J. Dynamic Modeling and Active Morphing Trajectory-Attitude Separation Control Approach for Gull-Wing Aircraft. IEEE Access 2017, 5, 17006–17019. [Google Scholar] [CrossRef] [Scilit]
- Yu, X.C.; Wang, Z.X.; Tan, W.; Wu, X.Y.; Li, J. A Review of Morphing Technology for Fixed-Wing Hybrid Aerial-Aquatic Vehicles (HAAV). Digit. Ocean Underw. Warf. 2025, 8, 47–53. (In Chinese) [Google Scholar]
- Yu, X.C.; Wang, Z.X.; Tan, W.; Wu, X.Y.; Li, J. Research Progress in Morphing Structure Design Technology for Cross-Domain Vehicles. Acta Aeronaut. Astronaut. Sin. 2024, 45, 231349. (In Chinese) [Google Scholar]
- Shao, D. Power Analysis of Cross-Domain Aircraft. Aviat. Power 2020, 1, 12–15. (In Chinese) [Google Scholar]
- Wu, Y.; Li, L.; Su, X.; Gao, B.W. Dynamics Modeling and Trajectory Optimization for Unmanned Aerial-Aquatic Vehicle Diving into the Water. Aerosp. Sci. Technol. 2019, 89, 220–229. [Google Scholar] [CrossRef] [Scilit]
- Zhen, Y.; Yuan, J.Q.; Chi, Q.X.; Wang, H.L.; Li, P. Research on the Application of Deep Reinforcement Learning Methods in Aircraft Control. Tactical Missile Technol. 2020, 4, 112–118. (In Chinese) [Google Scholar]
- Krawczyk, Z.; Vuppala, R.K.S.S.; Paul, R.; Kara, K. Urban Wind Field Effects on the Flight Dynamics of Fixed-Wing Drones. Drones 2025, 9, 362. [Google Scholar] [CrossRef] [Scilit]
- Abdolahipour, S. Effects of Low and High Frequency Actuation on Aerodynamic Performance of a Supercritical Airfoil. Front. Mech. Eng. 2023, 9, 1290074. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.J. Research on Attitude Control and Water-Exit Trajectory Optimization Design for Submarine-Launched Missiles. Ph.D. Thesis, Harbin Institute of Technology, Harbin, China, 2017. (In Chinese) [Google Scholar]
- Yang, G.T. Research on Modeling and Control Methods for Morphing Aircraft. Ph.D. Thesis, Beijing Institute of Technology, Beijing, China, 2015. (In Chinese) [Google Scholar]
- Yao, G.; Liang, J.; Wang, T.; Yang, X.; Li, Y. Submersible Unmanned Flying Boat: Design and Experiment. In Proceedings of the 2014 IEEE International Conference on Robotics and Biomimetics (ROBIO 2014), Bali, Indonesia, 5–10 December 2014; pp. 1308–1313. [Google Scholar]
- Tan, J.Y.; Hu, J.H.; Ma, Z.C.; Wang, C.; Li, H.Y. Research on Flight Path Angle Control during the Diving Process of Water-Air Cross-Domain Vehicles. Flight Dyn. 2019, 37, 34–38. (In Chinese) [Google Scholar]
- Park, H.; Choi, H. Aerodynamic Characteristics of Flying Fish in Gliding Flight. J. Exp. Biol. 2010, 213, 3269–3279. [Google Scholar] [CrossRef] [Scilit]
- Lock, R.J.; Vaidyanathan, R.; Burgess, S.C. Design and Experimental Verification of a Biologically Inspired Multi-Modal Wing for Aerial-Aquatic Robotic Vehicles. In Proceedings of the 2012 4th IEEE RAS and EMBS International Conference on Biomedical Robotics and Biomechatronics (BioRob), Rome, Italy, 24–27 June 2012; pp. 681–687. [Google Scholar]
- Siddall, R.; Ortega Ancel, A.; Kovač, M. Wind and Water Tunnel Testing of a Morphing Aquatic Micro Air Vehicle. Interface Focus 2017, 7, 20160085. [Google Scholar] [CrossRef] [Scilit]
- Weisler, W.; Stewart, W.; Anderson, M.B.; DeVries, L.; Epps, B.; Lentink, D. Testing and Characterization of a Fixed Wing Cross-Domain Unmanned Vehicle Operating in Aerial and Underwater Environments. IEEE J. Ocean. Eng. 2018, 43, 969–982. [Google Scholar] [CrossRef] [Scilit]
- Tan, Y.H.; Siddall, R.; Kovac, M. Efficient Aerial-Aquatic Locomotion with a Single Propulsion System. IEEE Robot. Autom. Lett. 2017, 2, 1304–1311. [Google Scholar] [CrossRef] [Scilit]
- Liang, J.H.; Yao, G.C.; Wang, T.M.; Yang, X.B.; Li, Y.M. Wing Load Investigation of the Plunge-Diving Locomotion of a Gannet Morus Inspired Submersible Aircraft. Sci. China Technol. Sci. 2014, 57, 390–402. [Google Scholar] [CrossRef] [Scilit]
- Wang, T.M.; Yang, X.B.; Liang, J.H.; Yao, G.C.; Li, Y.M. CFD Based Investigation on the Impact Acceleration When a Gannet Impacts with Water during Plunge Diving. Bioinspir. Biomim. 2013, 8, 036006. [Google Scholar] [CrossRef] [Scilit]
- Mao, J.Y.; Liu, F.; Wei, Z.P. Key Technologies and Development Trends of Lightweight and Small-Scale Cross-Domain Loitering Munition Clusters. J. Proj. Rocket. Missiles Guid. 2024, 44, 59–65. (In Chinese) [Google Scholar]
- Sun, D.P.; Feng, L.P.; Yan, G.Y. Analysis of the U.S. Military’s Blackwing UAV System and Its Operational Use. Winged Missile J. Feihang Daodan 2020, 9, 57–60. (In Chinese) [Google Scholar]
- Majumdar, D. US Navy Launches UAV from a Submarine. US Naval Inst. News 2013, 2, 31–42. [Google Scholar]
- Alzu’bi, H.; Mansour, I.; Rewashded, O. Loon Copter: Implementation of a Hybrid Unmanned Aquatic-Aerial Quadcopter with Active Buoyancy Control. J. Field Robot. 2018, 35, 764–778. [Google Scholar] [CrossRef] [Scilit]
- Eubank, R.D.; Atkins, E. Unattended Autonomous Mission and System Management of an Unmanned Seaplane. In Proceedings of the Infotech@Aerospace Conferences, St. Louis, MO, USA, 29–31 March 2011; p. AIAA 2011-1614. [Google Scholar]
- Eubank, R.D.; Bradley, J.M.; Atkins, E.M. Energy-Aware Multiflight Planning for an Unattended Seaplane: Flying Fish. J. Aerosp. Inf. Syst. 2017, 14, 73–91. [Google Scholar] [CrossRef] [Scilit]
- Bowman, J.; Sanders, B.; Cannon, B.; Kudva, J.; Joshi, S.; Weisshaar, T. Development of Next Generation Morphing Aircraft Structures. In Proceedings of the 48th AIAA/ASME/ASCE/AHS/ASC Structures, Structural Dynamics, and Materials Conference, Honolulu, HI, USA, 23–26 April 2007; p. 1730. [Google Scholar]




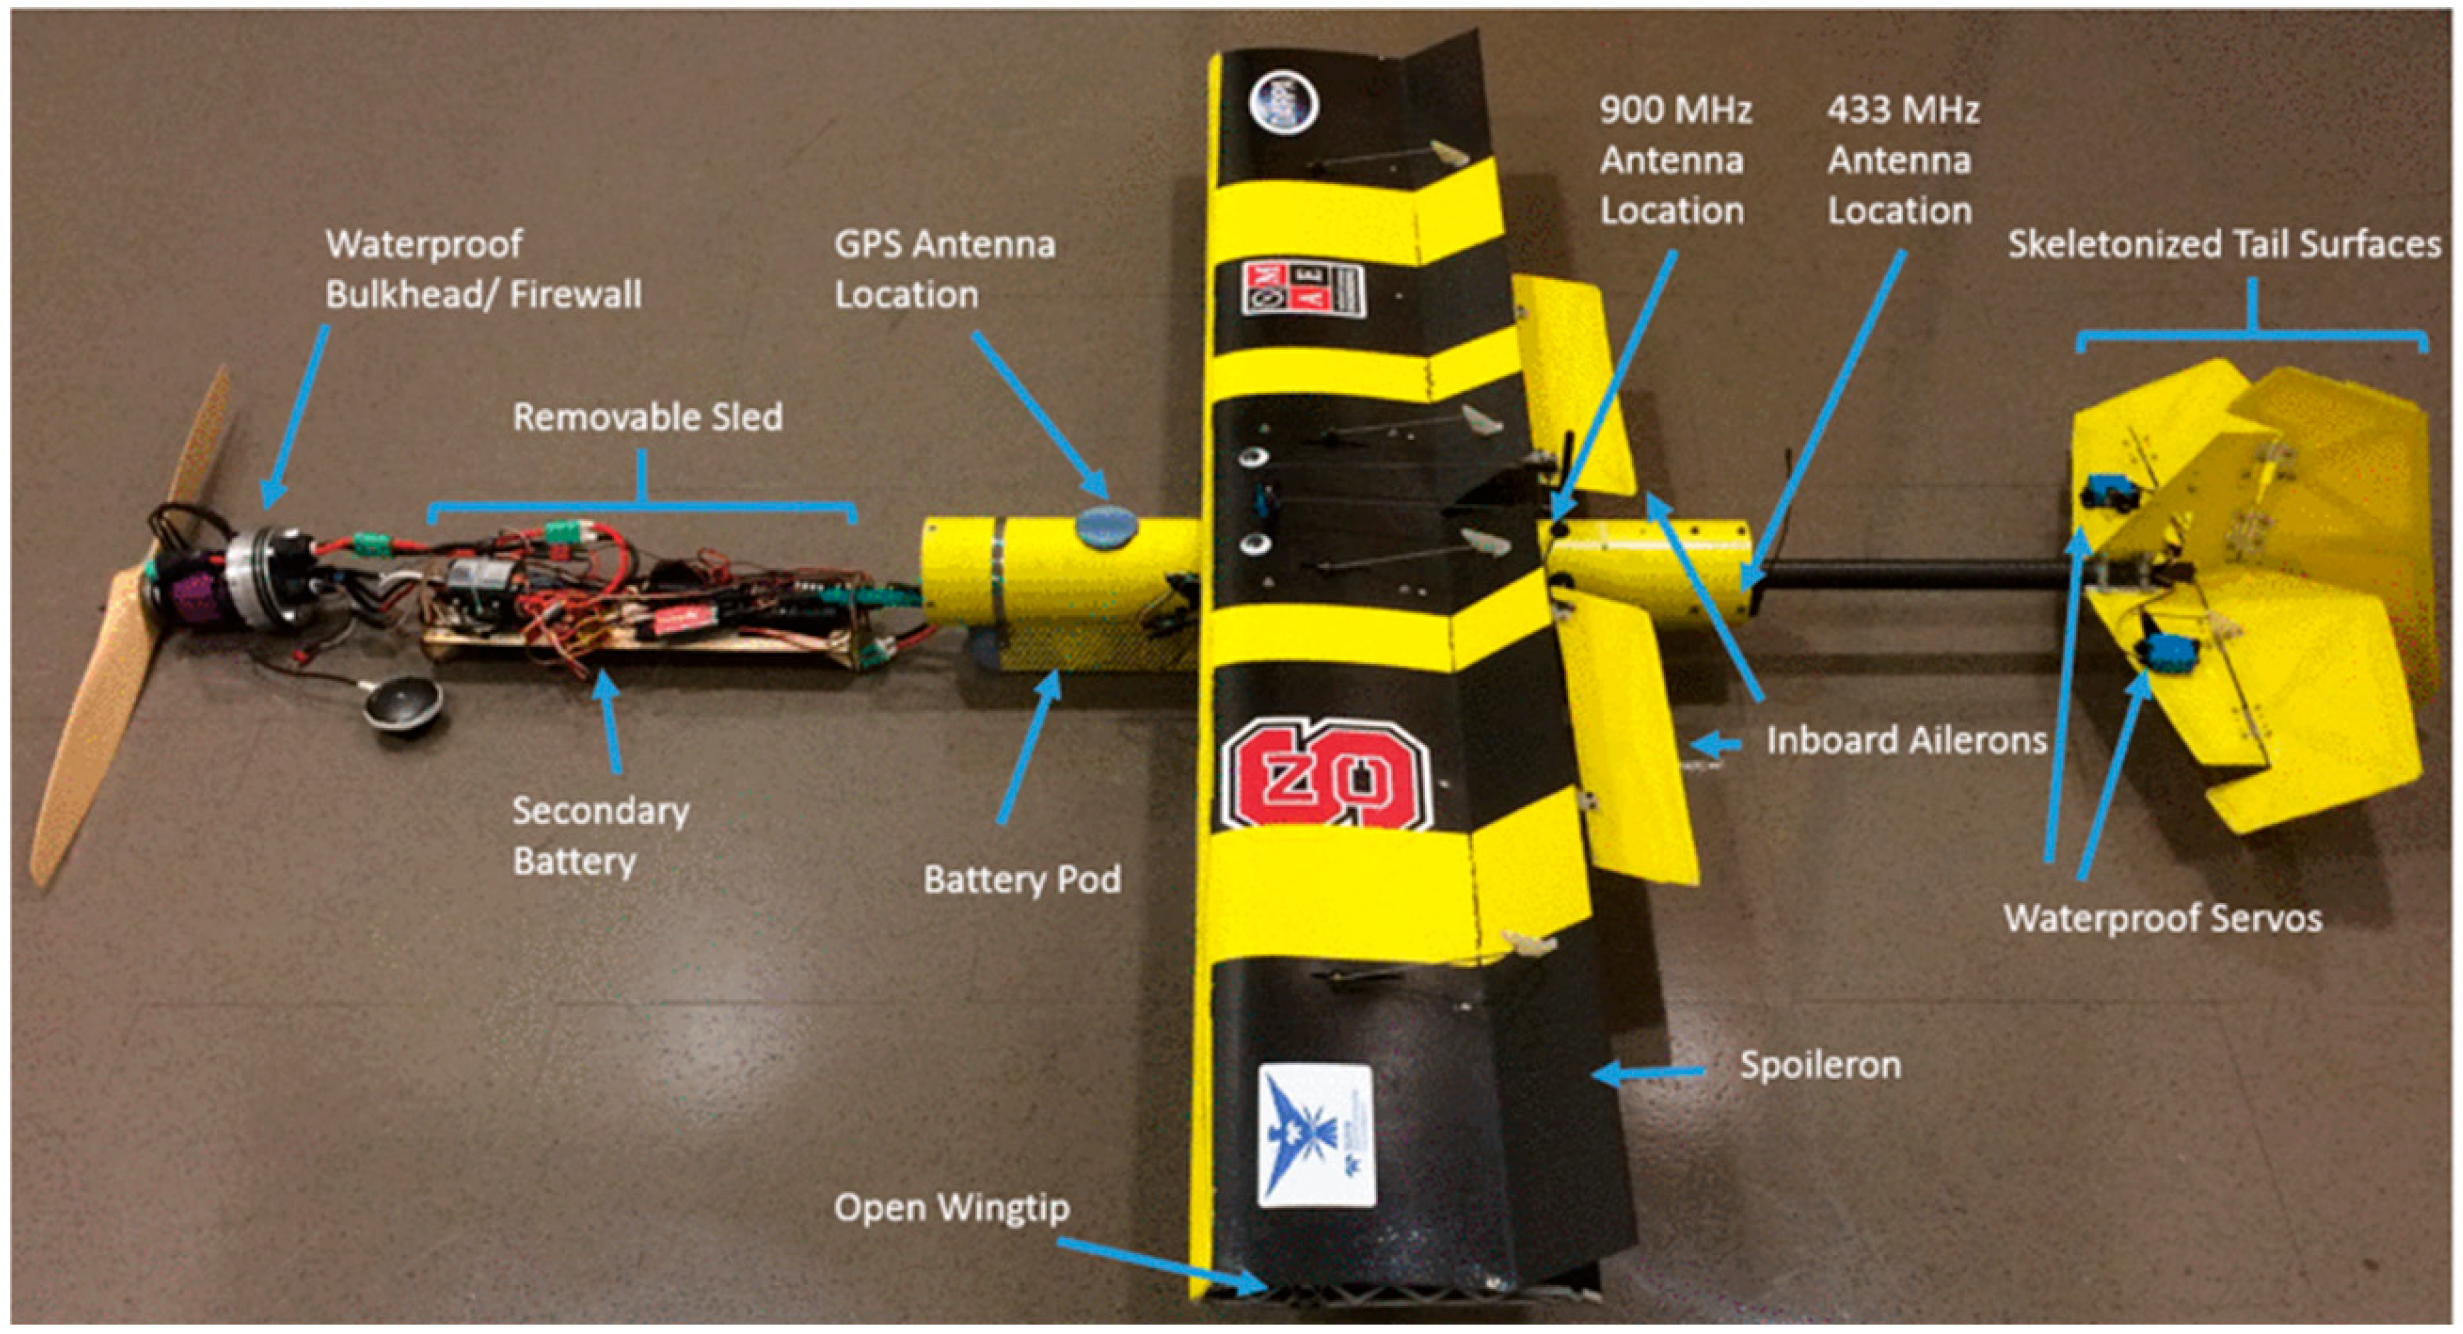




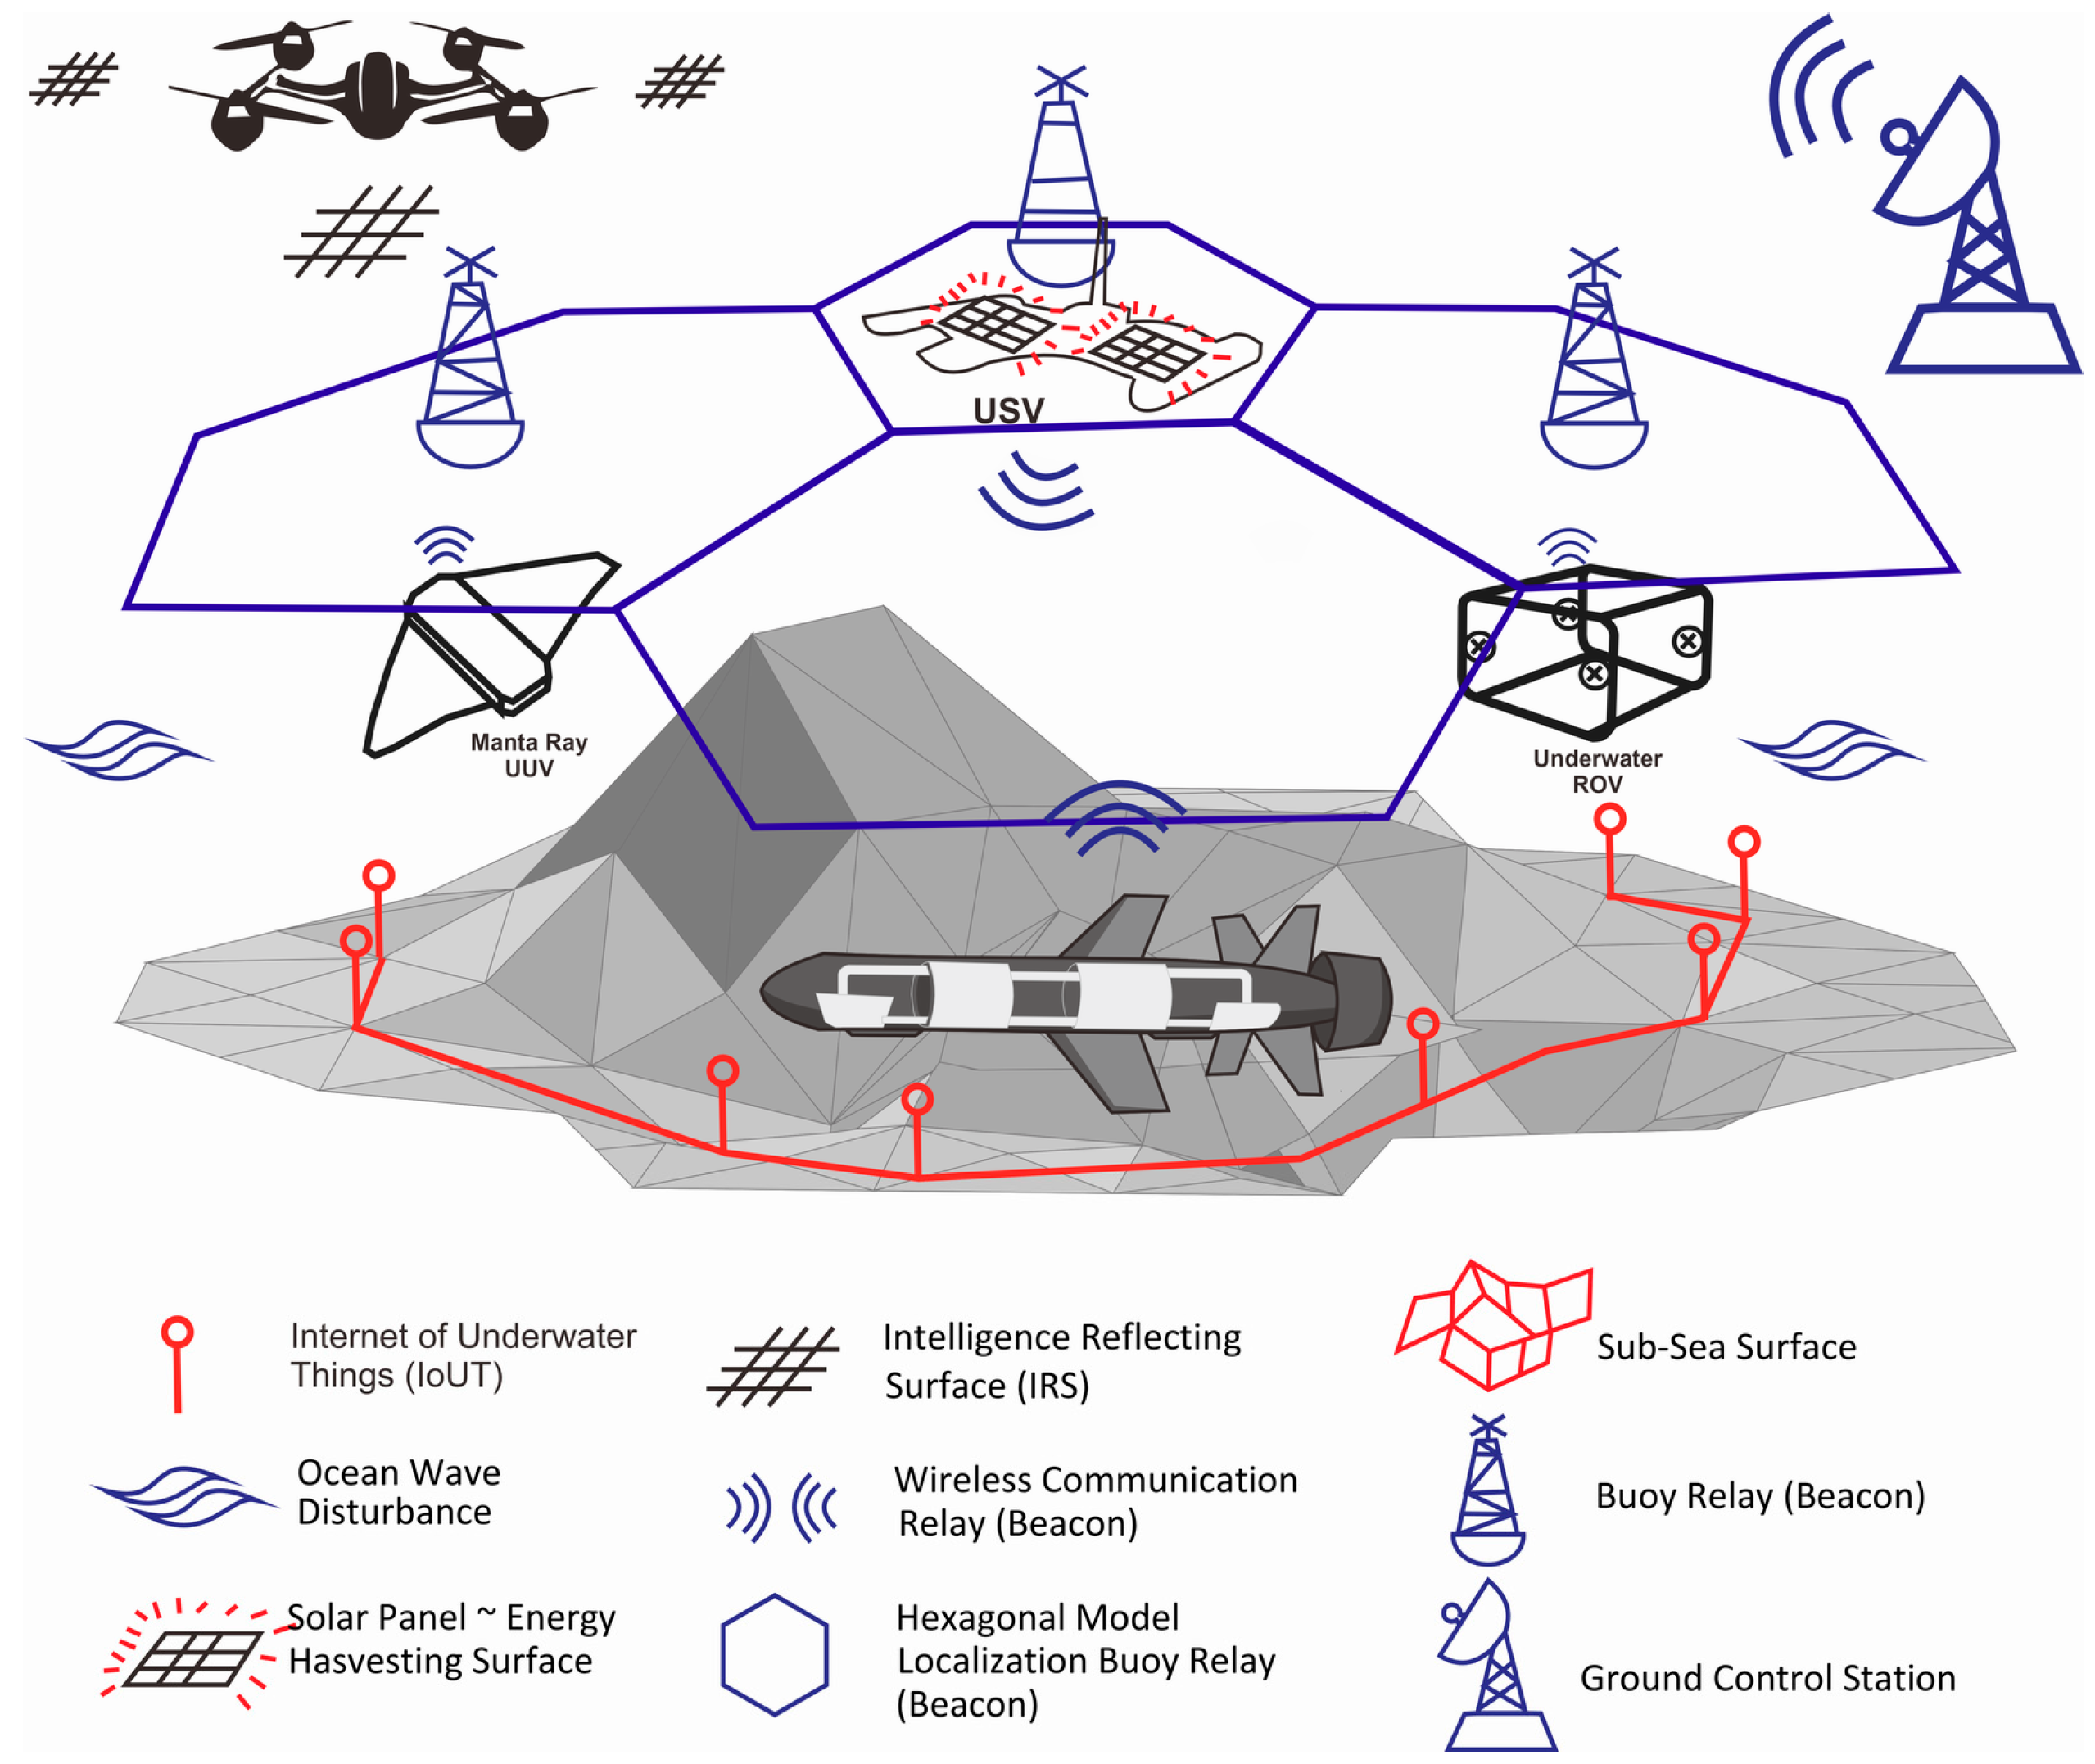

| Name | “Cormorant” | “Flying Fish” | “Booby” | AquaMAV | “Kingdee” | “Longbow 2” |
|---|---|---|---|---|---|---|
| Research Institution | Lockheed Martin | Beihang University | Beihang University | Imperial College London | Central South University | Harbin Engineering University |
| Year | 2005 | 2009 | 2013 | 2014 | 2020 | 2022 |
| Aerofoil Structure | Lateral folding wings | Lateral folding wings | Lateral folding wings (0–60°) | Lateral folding wings | Three-stage folding wing | Lateral folding wings |
| Aerial Propulsion Method | Turbofan engine | Propeller | Propeller | Propeller | Electric propulsion | Piston Engine |
| Underwater Propulsion Method | - | Electric propulsion | Electric propulsion | water jet | Electric propulsion | Electric Propulsion |
| Air Speed (km/h) | 800 | 45 | 60 | 40 | 54 | 120 |
| Endurance (min) | 15 | 30 | 40 | 14 | 40 | 120 |
| Underwater Speed (m/s) | - | 1 | 1.5 | 1.2 | 1.5 | 3 |
| Submersion Depth (m) | - | 10 | 5 | 5 | 8 | 30 |
| Water-to-Air Transition Method | Steam catapult (single use) | Water-ski takeoff | Propeller takeoff | water jet | Propeller takeoff | Surface Skimming Takeoff |
| Air-to-Water Transition Method | Splashdown | Splashdown | Dive into the water | Splashdown | Splashdown | Controllable Water Entry |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Share and Cite
Tu, J.; Zhuang, J.; Chen, H.; Zhao, C.; Zhang, H.; Gan, W. Advances in Folding-Wing Flying Underwater Drone (FUD) Technology. Drones 2026, 10, 62. https://doi.org/10.3390/drones10010062
Tu J, Zhuang J, Chen H, Zhao C, Zhang H, Gan W. Advances in Folding-Wing Flying Underwater Drone (FUD) Technology. Drones. 2026; 10(1):62. https://doi.org/10.3390/drones10010062
Chicago/Turabian StyleTu, Jianqiu, Junjie Zhuang, Haixin Chen, Changjian Zhao, Hairui Zhang, and Wenbiao Gan. 2026. "Advances in Folding-Wing Flying Underwater Drone (FUD) Technology" Drones 10, no. 1: 62. https://doi.org/10.3390/drones10010062
APA StyleTu, J., Zhuang, J., Chen, H., Zhao, C., Zhang, H., & Gan, W. (2026). Advances in Folding-Wing Flying Underwater Drone (FUD) Technology. Drones, 10(1), 62. https://doi.org/10.3390/drones10010062