


Abstract
This work aims to introduce the concept of graphic rational contractions in the framework of extended -metric spaces and to establish fixed point theorems related to these mappings. In addition, we define and examine the class of interpolative Ćirić–Reich–Rus-type cyclic contractions in the same setting, deriving several new fixed point results that broaden existing theories. To illustrate the validity and originality of the obtained results, appropriate examples are presented. Furthermore, the developed theoretical results are applied to study the existence of solutions for fractional differential equations and nonlinear mixed Volterra–Fredholm integral equations, highlighting their effectiveness and practical importance.
Keywords:
fixed points; extended ℱ-metric spaces; interpolative Ćirić-Reich-Rus-type cyclic contraction; fractional differential equations; nonlinear mixed Volterra–Fredholm integral equations MSC:
34A08; 47H10; 54H25
1. Introduction
The field of fixed point (fp) theory remains one of the most active and captivating branches of modern mathematical analysis, largely due to its deep connections with the structure of metric spaces (mss), which provide a rigorous framework for measuring distances and analyzing convergence, thereby offering an ideal setting for investigating the existence and uniqueness of fps. The notion of a ms, introduced by Fréchet [1], represents one of the central foundations of modern mathematics. Owing to its broad applicability in analysis and related disciplines, this concept has been extended and refined in numerous directions. Over time, various meaningful advancements of mss have been proposed. In this context, Bakhtin [2] introduced an important extension which was subsequently developed by Czerwik [3] under the name of b-ms, where the classical triangle inequality is transformed by incorporating a real number . This adjustment significantly broadened the scope of analytical techniques and applications.
Subsequently, Fagin et al. [4] introduced the thought of an s-relaxedp metric and demonstrated that each of these spaces satisfies the conditions of a b-ms, although the reverse implication does not generally hold. Khamsi et al. [5] later reexamined this framework under the terminology of mss, establishing several fp results in this setting. Branciari [6] further generalized the structure by defining rectangular mss, replacing the conventional triangle inequality by a four-point rectangular inequality. Building on this progress, Jleli et al. [7] put forward the concept of an -ms, which unifies and extends some earlier thoughts.
In current research, Panda et al. [8] enhanced the conception of -mss by defining a new structure called an extended -ms (-ms). This new framework generalizes the classical -metric structure by allowing greater flexibility in the definition of the distance function, thereby accommodating a wider class of mappings and operators. Albargi et al. [9] defined the notion of Kannan-type interpolative cyclic contractions and proved some new fp theorems for such contractions.
Building on these successive generalizations of mss, one of the primary motivations has been to extend cornerstone results in fp theory to more flexible frameworks. Among these, the Banach contraction principle [10] stands as the earliest and most fundamental theorem, guaranteeing the existence and uniqueness of a fp for continuous self-mappings satisfying a contraction condition. Thereafter, Kannan [11] loosened the continuity assumption and developed a fp result subject to a less restrictive contractive condition. Reich [12] unified the contractive conditions of Banach and Kannan by establishing a more general fp theorem, thereby extending the scope of classical contraction principles. This theory has undergone significant generalizations beyond classical ms to accommodate more complex structures and relationships among elements. One such direction was initiated by Jachymski [13], who in 2008 introduced the notion of graphic contractions in mss endowed with a directed graph. This approach arose from the observation that many mappings arising in applied sciences, economics, and computer science naturally preserve certain relational structures, which cannot be captured by the ordinary metric framework alone. By embedding a graph structure on the underlying set, Jachymski [13] unified and extended several existing fp theorems, particularly the BCP to cases where the contractive condition is required only along edges of the graph rather than globally. Subsequently, Bojor [14] advanced the incorporation of graph structures into fp theory and established a result that generalizes Kannan’s fp theorem. Additional insights can be found in [15,16].
In recent decades, many researchers have focused on extending and refining these classical results by introducing more general and flexible contractive conditions, which led to the development of interpolative and hybrid contraction mappings. Kirk et al. [17] presented the notion of cyclic contractions to analyze mappings alternating linking distinct subsets of a ms. Inspired by these advancements, Karapınar [18] proposed the idea of interpolative Kannan-type contractions, providing deeper insights into the relationship among classical and contemporary contraction principles and fostering further progress in generalized metric structures. Subsequently, Karapınar et al. [19] introduced interpolative Reich–Rus–Ćirić type contractions within the framework of partial mss, thereby extending the earlier concept of interpolative Kannan-type contractions. Thangaraj et al. [20] introduced a controlled Kannan iterated function system and developed the concepts of controlled Kannan attractors and multivalued fractals by extending the Kannan fp theorem to new generalized mss. Hussain et al. [21] contributed to the development of -mss by establishing several generalized fp theorems within this setting. Subsequently, Al-Mazrooei et al. [22] investigated fp problems for rational-type contractions with non-negative parameters in -mss. In due course, Alnaser et al. [23] additionally expanded this framework by deriving new fp theorems and applying them to the study of some differential equations. In addition, Hussain et al. [24,25,26] extended the theory by solving different fractional differential equations. Additional contributions and related advancements in this area are discussed in [27,28].
The present study is devoted to develop novel fp theorems in the framework of -mss, focusing on two main directions:
1. Graphic rational contractions in -mss: We introduce the concept of graphic rational contractions, which combine the flexibility of -metrics with the structure of directed graphs, allowing the study of self-mappings that preserve relational constraints among elements. For these mappings, we establish several new existence and uniqueness results for fps.
2. Interpolative Ćirić–Reich–Rus-type cyclic contractions: We extend classical cyclic and interpolative contraction principles to -mss, unifying and generalizing earlier results such as Kannan, Reich, and cyclic contraction theorems. This framework provides a robust tool for analyzing mappings alternating among subsets of a ms.
To demonstrate the practical relevance of the proposed theory, we provide illustrative examples and apply the results to investigate the solution of fractional differential equations and nonlinear Volterra integral equations, highlighting both theoretical depth and applicability.
The remainder of the research article is organized as follows:
Section 2 presents essential preliminaries, including fundamental notions of ms, -ms, and an -ms, together with classical and generalized contraction mappings. These concepts lay the groundwork for the main theoretical developments.
Section 3 contains the principal results, where we introduce graphic rational contractions and interpolative Ćirić–Reich–Rus-type cyclic contractions in -mss, establishing corresponding fp theorems that generalize and amalgamate several prior results.
Section 4 illustrates the applicability of the obtained theorems by solving fractional differential equations and nonlinear Volterra integral equations, highlighting the practical significance of the theoretical findings.
2. Preliminaries
We begin this section by outlining the necessary definitions, supporting lemmas, and foundational concepts that underpin the main results presented later.
The concept of a ms was introduced by Fréchet [1] as follows:
Definition 1 ([1]).
Let . A function is a metric if, for all :
and ⟺
The couple is called a ms.
In [3], Czerwik formulated the definition of a b-ms in such fashion.
Definition 2 ([3]).
Let and . A real-valued function is said to be a b-metric if it satisfies ()-(), and, for all :
The pair is called a b-ms.
According to Fagin et al. [4] an s-relaxed p-ms is described as follows:
Definition 3 ([4]).
Let , and let fulfill conditions ()- and
- (Dsp3)
- there exists such that, for any two points , for every integer (set of natural numbers), , and for any finite sequence with , the inequalityis satisfied. In this case, the ordered pair is called an s-relaxed p-ms.
Jleli et al. [7] introduced a significant extension of the classical notion of a ms through the formulation of the thought of an -ms.
Let represents the family of mappings satisfying the following conditions:
- ()
- ℏ is non-decreasing, that is, for all we have
- ()
- for any sequence ,
Definition 4 ([7]).
Let , and let . Suppose there exists a pair such that d fulfills conditions and and in addition fulfills the following inequality:
- ()
- for any couple for each integer , and for any sequence with the implicationholds. On the basis of these assumptions, the function d is called an -metric on X, and the couple is said to be an -ms.
Panda et al. [8] gave the idea of an extended -ms (-ms) in this manner.
Definition 5 ([8]).
Let , and let . Suppose that there exists a pair such that d satisfy fulfills conditions and and additionally satisfies the inequality given below:
- ()
- there exists such that, for every couple and each integer , if is a sequence with , thenUnder these assumptions, is called an -ms.
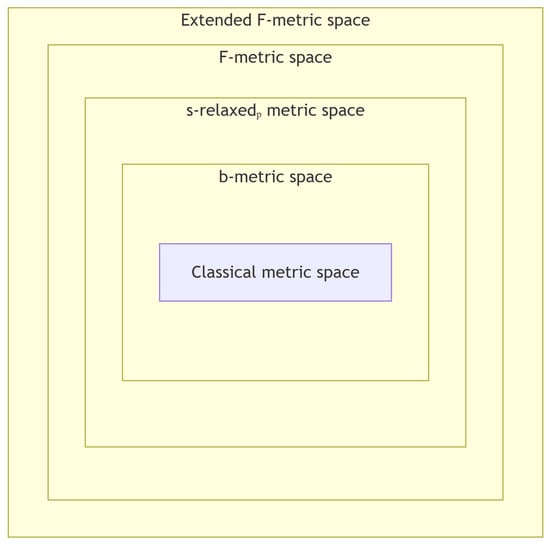
Note that each -ms is an -ms when the control function for all The additional function in the extended setting serves as a variable control that adjusts the influence of intermediate distances in the generalized triangle inequality. This extra flexibility allows the -metric framework to encompass a wider range of generalized distance structures and to handle situations where uniform control (as in the -metric case) is too restrictive. Consequently, the concept of -ms unifies and extends the metric, b-metric, s-relaxedp-metric, and -mss, providing a richer environment for developing new fp results and their applications.
The following diagram (Figure 1) summarizes the hierarchy of extended -metric spaces.
Figure 1.
Relationship among extended -metric space and its special cases.
Definition 6 ([8]).
Let be an -ms.
(1) -Convergence: A sequence in X is said to be -convergent to if is converges to υ with respect to an -metric d.
(2) -Cauchy Sequence: A sequence in X is called -Cauchy, if
(3) -Completeness: The space is -complete if every -Cauchy sequence in X is -convergent to some element of X.
Remark 1.
It follows directly from the definitions that every -ms is automatically an -ms, however, the reverse implication is not valid in general. In fact, by taking
the generalized condition corresponding to an -ms reduces precisely to condition that characterizes an -ms. Consequently, the concept of an -ms proposed by Panda et al. [8] strictly extends the framework of -ms introduced by Jleli et al. [7].
Theorem 1.
(Classical Fixed Point Results). Let () be a complete MS.
- Banach Contraction Principle: If satisfiesfor some then ℜ has a unique fp.
- Kannan’s Fixed Point Theorem: If satisfiesfor some then ℜ has a unique fp.
- Fixed Point Result for Cyclic Contraction: If satisfy the followingandfor all and some then ℜ has a unique fp in , where and are two nonempty closed subsets of
- Fixed Point Theorem for Interpolative Contraction: If satisfiesfor all where and for some and , then ℜ has a unique fp in
- Fixed Point Result for Graphic Contraction: Let be a complete ms associated with a directed graph and let Suppose
(a) ℜ is edge-preserving, that is, for all with we have
(b) there exists such that, ∀ with , we have
and there exists with then ℜ has a fp in Moreover, if G is weakly connetced, then this fp is unique.
3. Main Results
The primary results of this work are established in this section. We begin by introducing the concept of graphic rational contractions within the framework of -mss and establish several fp theorems associated with these self-mappings. Subsequently, we define the notion of interpolative Ćirić–Reich–Rus-type cyclic contractions in the same setting and derive corresponding fp theorems that further broaden and consolidate existing theories.
Let be a directed graph associated with an -ms
- is a nonempty set whose elements are called vertices;
- is a set of directed edges (or arcs) between the vertices.
The graph G is said to be loop-inclusive if every vertex is connected to itself; that is,
Furthermore, G is assumed to contain no multiple edges, meaning that between any ordered pair of vertices there exists at most one directed edge.
A path from to in G of length N (a natural number) is a sequence of vertices such that , and ∀ Let denote the symmetric graph obtained from G by ignoring the direction of edges, i.e.,
where is the converse graph of G, defined by
The graph G is said to be weakly connected if the symmetric graph is connected, i.e., if for any two distinct vertices , there exists a path from to in
Definition 7.
Let be an -ms equipped with a directed graph G. A self-mapping is said to be graphic rational contraction if
(i) ℜ is edge-preserving, that is, for all
(ii) there exists some with such that for all , we have
Theorem 2.
Let be an -complete -ms endowed with a directed graph and let be a graphic rational contraction with constant . Suppose that the following assertions hold:
(i) there exists a such that
(ii) for any initial point the sequence {} defined by satisfy
where
(iii) either ℜ is G-continuous or, if is a sequence such that as and then , ∀ Then ℜ has a fp.
Moreover, ℜ has a unique fp if in addition
(iv) for any two fps , there exists a finite directed path in G joining and (i.e., G is path-connected on the set of fps).
Proof.
Let with Define the iterative sequence
for all By edge-preserving property (1) and the fact for it follows inductively that
for all Apply (2) to successive pairs to obtain
By induction,
for all For consider the chain (( Then using the -metric triangle inequality (), we have
Since
By using the inequality (4), we have
By substituting inequality (5) into (4) and using the property (), we have
Since the series converges (by the ratio test). Let
and
Since
for Since converges, so there exists some such that
for Since by condition (), for the fixed number there is such that
Now by (7), (8) and (9), we have
for Thus, by (6) and (10), we have
This shows, by condition () that for all we have proving that the sequence {} is -Cauchy. As is -complete, a point exists such that is -convergent to under the -metric, i.e.,
Next, we show that is a fp of self-mapping ℜ Suppose ℜ is G-continuous. Since
by G-continuity of we have
Taking the limit in (3) as we obtain
Hence, is a fp of Further if is a sequence such that as and then by the assumption, we get , ∀ Now apply the contraction (2) to each pair That yields by (2)
By (), we have
Since
So, by (12) and (), we have , i.e. . Thus, is a fp of Now we prove the uniqueness of fp. We start by supposing that, for the sake of contradiction, that ℜ has two fps, that are, such that and but By assumption (iv), there exists a finite directed path { such that and for all . We prove by induction that
for all
For , since applying the contraction condition (2) gives
Since is a fp of then Therefore,
Since this inequality implies Hence, Assume now that
for some We need to show . Since and (by the induction hypothesis), we have
Applying (2) and using the fact that we have
Because we must have which implies By induction, we conclude that Since by the definition of the directed path, we have This contradicts our initial assumption that Hence, fp is unique. □
As a special case of our main Theorem 2, we recover the well-known fp result established by Panda et al. [8] for contraction mappings in -mss. This demonstrates that our theorem not only generalizes existing results but also unifies earlier contraction principles within a broader graph-theoretic framework.
Corollary 1 ([8]).
Let be an -complete -ms. Suppose satisfies
for some constant Then ℜ has a unique fp in
Proof.
Apply Theorem 2 with the directed graph □
Remark 2.
(i) By defining the control function as in Definition 5, the -ms reduces to a standard -ms. Consequently, Theorem 2 coincides with the main result of Jleli et al. [7].
(ii) If we choose for and for and define in Definition 5, then the -ms reduces to a b-ms. Considering the graph Theorem 2 specializes to the leading fp theorem of Czerwik [3].
(iii) Defining and choosing for with in Definition 5, the -ms reduces to a classical ms. In this case, Theorem 2 recovers the well-known fp theorem of Jachymski [13].
(iv) Finally, by taking along with the setting in (iii), Theorem 2 reduces to the classical Banach contraction principle [10].
Example 1.
Let . Define the -metric (non-negative real numbers) by
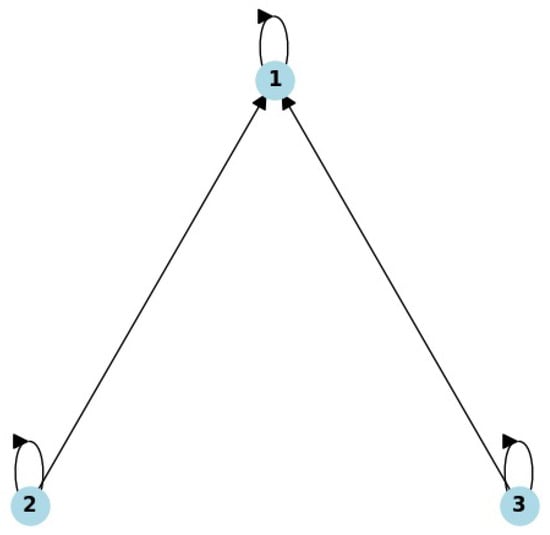
and the function by Then is an -ms with for and . Moreover, the set X is finite, so an -ms is -complete. Define the directed graph by specifying the edge set
(i.e., edges and plus self-loops). The structure of the directed graph is illustrated in Figure 2.
Figure 2.
Graphical representation of the directed graph .
Define the self-mapping by
Now if then equals either or or each of which is in So (1) holds. Now if
then
If
then
Thus, the inequality (2) holds with and . Hence, the self-mapping is a graphic rational contraction. Take Then
So condition (i) of Theorem 2 is satisfied. For any initial the Picard sequence for all from any start becomes eventually or So and as Thus, we have
Therefore,
Thus, the condition (ii) holds. Since X is finite, so every function is continuous with respect to Hence, ℜ is continuous and therefore G-continuous. So condition (iii) holds. All hypotheses of the Theorem 2 are satisfied, so ℜ has a fp. Indeed . However, the main result of Panda et al. [8] (the Banach-type contraction theorem in -mss) is not applicable here, since the contractive condition fails for the non-edge pair Indeed,
showing that no global contraction constant can satisfy the required inequality for all pairs in Hence, the result of [8] cannot be applied, while our graph-based theorem remains valid.
Example 2.
Let . Define the -metric by
and the function by Then is an -ms with for and . Moreover, the set X is finite, so an -ms is -complete. Define the directed graph by specifying the edge set
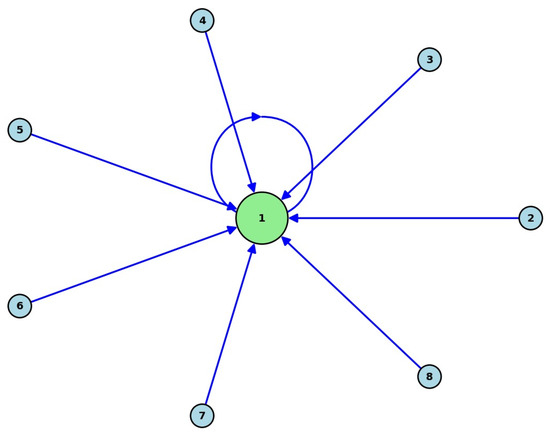
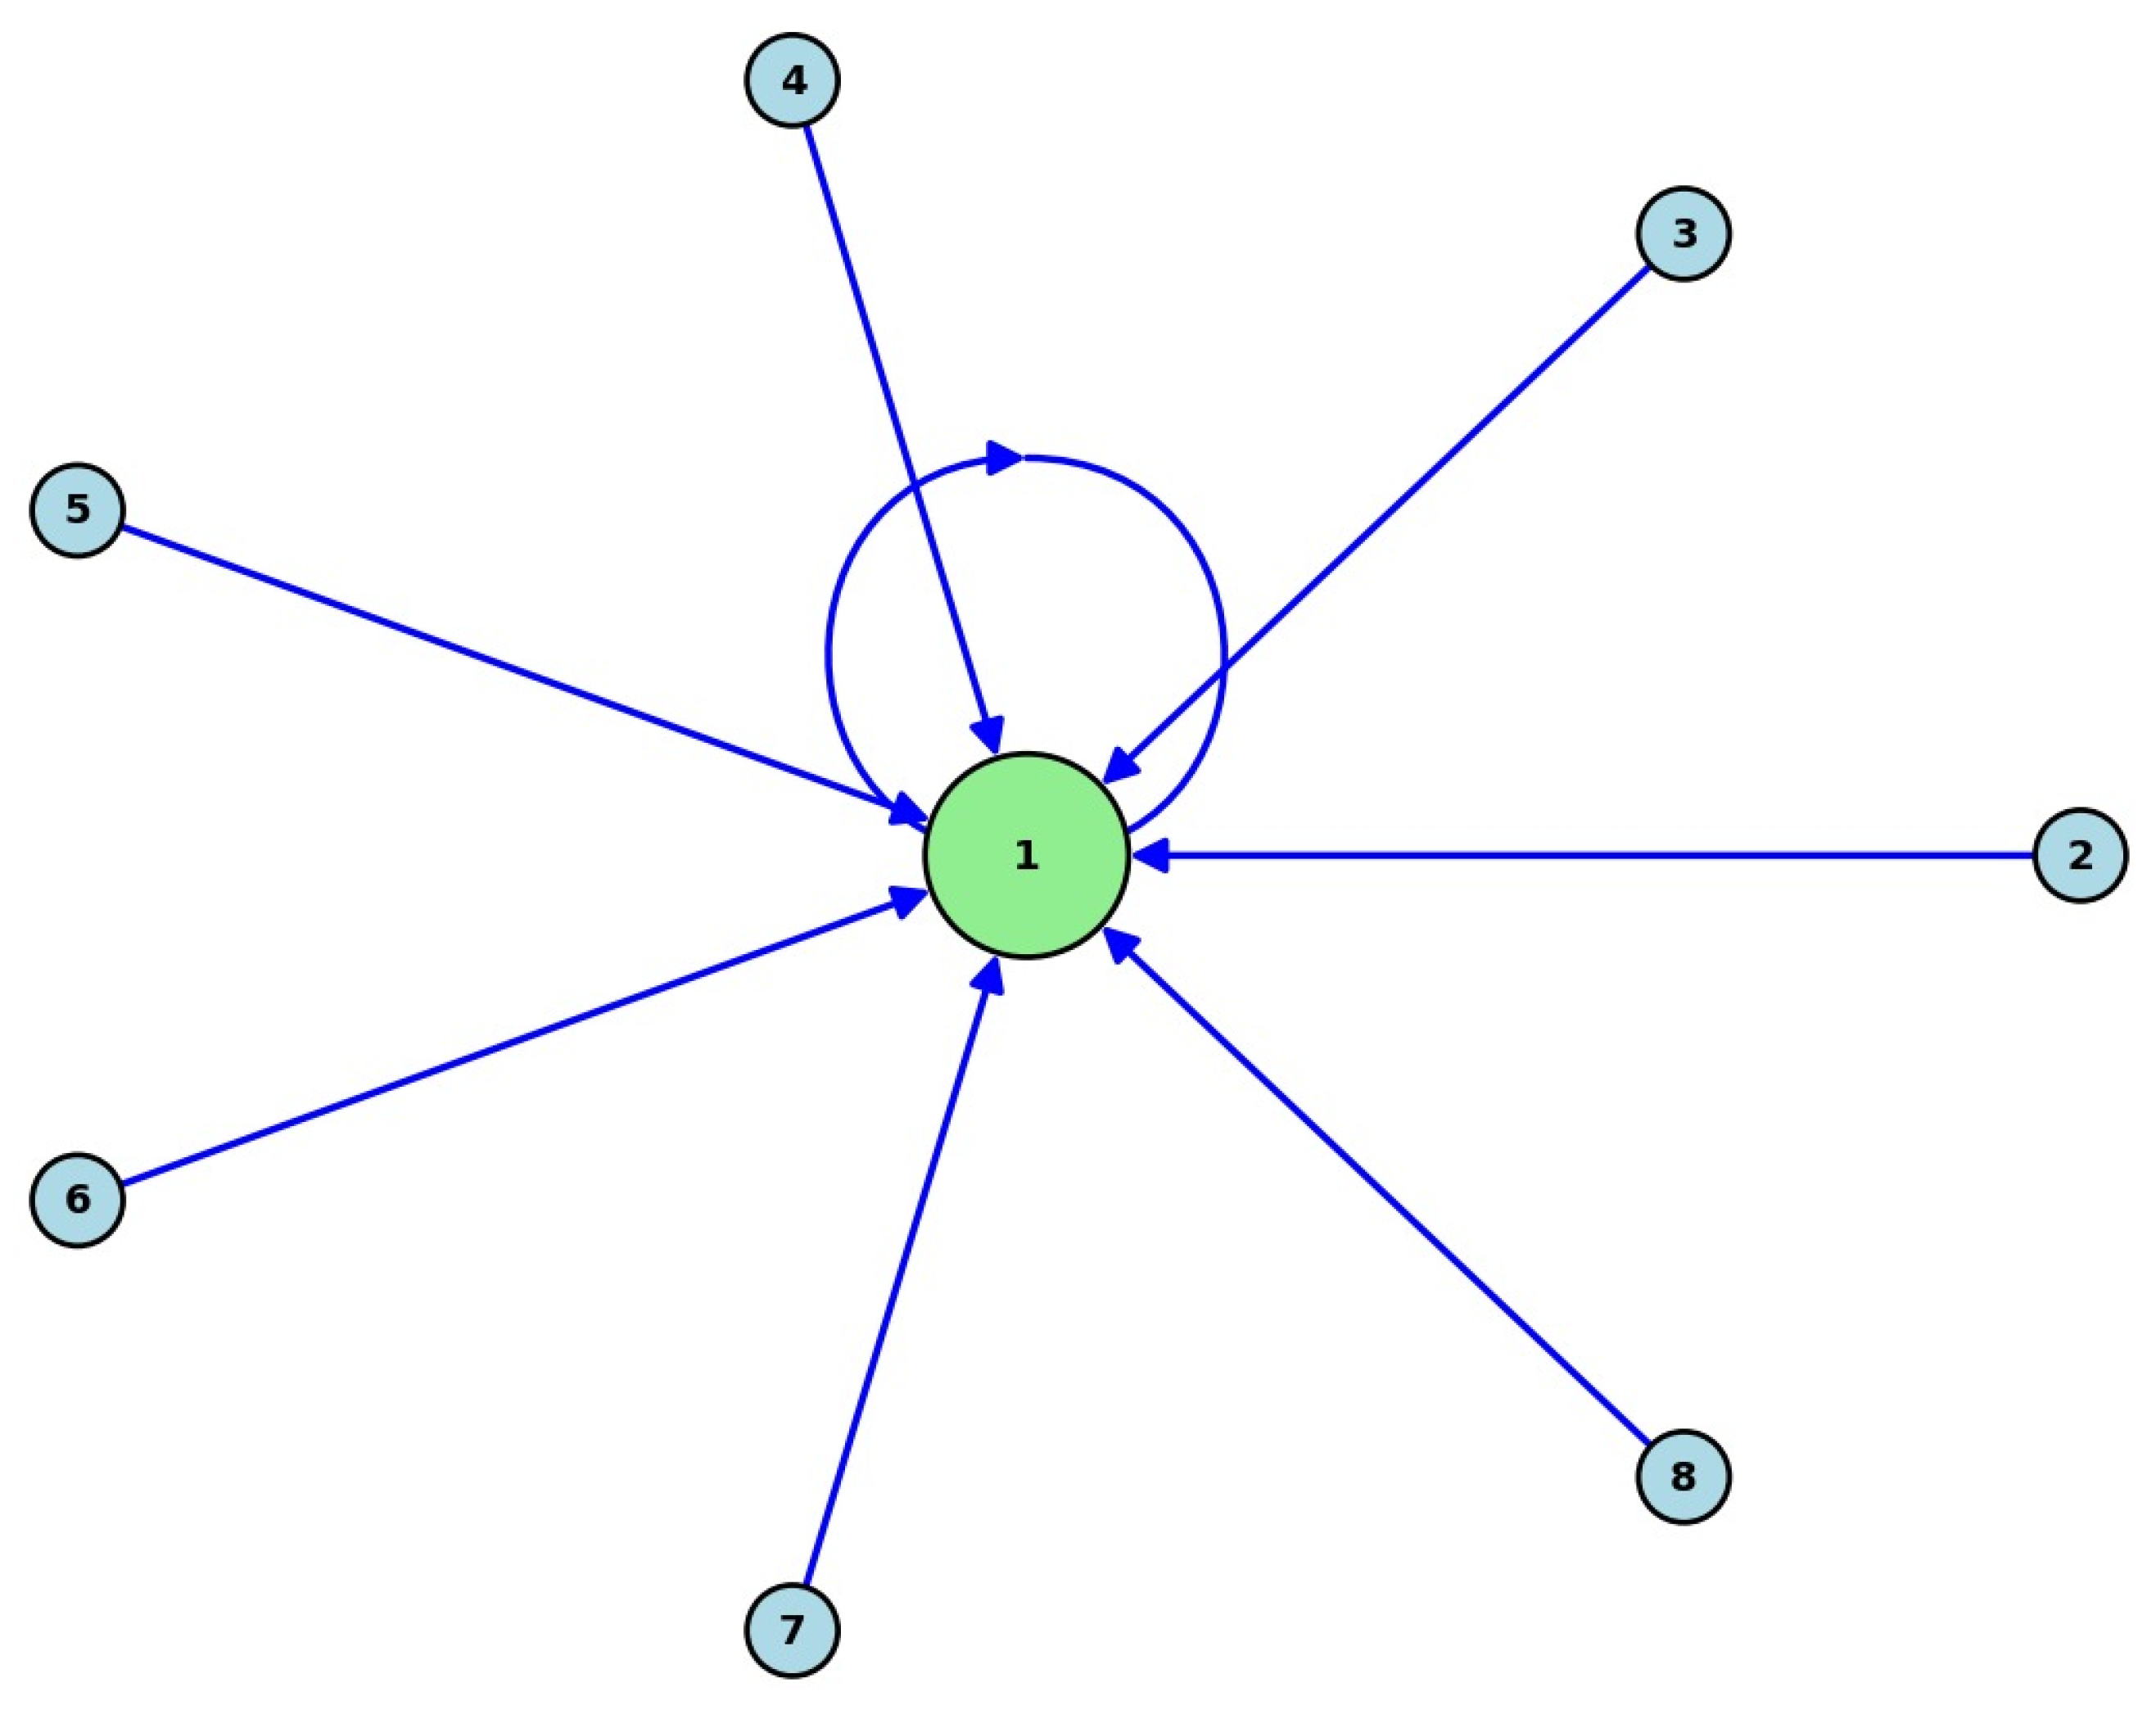
So every vertex has a directed edge to 1, and 1 has a self-loop.
Define the self-mapping by
for every Now for we have
Thus, ℜ is edge-preserving. Now if then either (so ) or and (so ). In every case
for and Thus, the inequality (2) holds. Hence, the self-mapping is a graphic contraction. Let Then and by definition. So condition (i) of Theorem 2 is satisfied. For any initial define the Picard sequence for all Because ℜ is constant equal to 1, we have
So and as Thus, we have
Therefore,
Thus, the condition (ii) holds. The mapping ℜ is constant, hence continuous and therefore G-continuous. So condition (iii) holds. All hypotheses of the Theorem 2 are satisfied; hence,
so 1 is a fp. Figure 3 displays the directed graph , with its vertices and edge relations.
Figure 3.
The directed graph .
Definition 8.
Let be an -ms and let be non-empty subsets. A self mapping ℜ is said to be an interpolative Ćirić–Reich–Rus-type cyclic contraction if there exist and positive reals such that and
for all with , where represents the collection of all fps of ℜ.
Example 3.
Let . Define by
and by Select by for and , then () is an -ms. Define two non-empty subsets
Clearly,
Define a mapping by
for all Then
so ℜ is cyclic. Moreover,
Choose positive constants
so and For any with we have
On the other hand,
Hence,
for all with Therefore, ℜ is an interpolative Ćirić–Reich–Rus-type cyclic contraction on
Theorem 3.
Let be an -complete -ms and let be non-empty subsets. If ℜ is an interpolative Ćirić–Reich–Rus-type cyclic contraction. Given any starting point consider the sequence {} generated recursively by
If
where then ℜ has a unique fp in
Proof.
Consider the sequence defined recursively as
Set then
and so forth. In view of (13), we obtain
which implies that
that is,
∀ where In the same way, through (13), we have
which implies that
that is,
∀ where It follows from (14) and (15) that
∀ By following the same approach as in the proof of Theorem 2, we conclude that the sequence {} is -Cauchy. Because is -complete, there exists a point to which the sequence converges in the -metric; that is,
It is evident that the subsequence {} lies entirely in while {} belongs to Because both subsequences approach the same point we conclude that Next, we verify that is indeed a fp of ℜ By (), we get
Since
Hence, using (17) and condition (), we obtain , which implies . Therefore, is a fp of Assuming the opposite for contradiction, suppose that ℜ has two fps and , so that
Then
By (13), we have
whcih is possible only if □
This theorem generalizes classical cyclic contraction results to the framework of -mss by introducing an interpolative control involving the parameters and The inequality (13) balances the distances and , allowing the contraction strength to vary adaptively between iterates. The restriction guarantees that the overall contractive influence remains below unity, leading to convergence of the generated sequence toward a unique fp in Hence, this result unifies and extends various cyclic and interpolative fp theorems from metric, -metric, and -metric settings.
As a special case of Theorem 3, we now present a fp result for interpolative Ćirić–Reich–Rus-type contractions in an -complete -ms, obtained by removing the cyclic structure (i.e., taking
Corollary 2.
Let be an -complete -ms and let . Suppose the existence of and positive reals such that and
with . Given any starting point consider the sequence {} generated recursively by
If
where then ℜ has a unique fp in
Proof.
The result follows directly from Theorem 3 by setting thereby eliminating the cyclic condition. □
Remark 3.
Similar to Remark 2, by defining the control function as
in Definition 5, the -ms reduces to an -ms. Consequently, the corresponding result for interpolative Ćirić–Reich–Rus-type cyclic contractions in the framework of an -mss can be deduced directly from Theorem 3.
Moreover, analogous results in b-mss and classical mss can be obtained by taking for and with and further letting respectively.
Example 4.
Let . Define by
∀ and by Select by for and , then () is an -complete -ms. Take
Then and Consider a cyclic mapping defined by
then Choose positive constants
so and For all pairs in the set , we find
In fact, when it holds that
Now define the orbit: for any
Each sequence converges to
Therefore, and so we have
so,
Now compute
Hence,
This fulfills the additional sequence requirement of Theorem 3, and hence, ℜ has a unique fp at .
4. Applications
The theory of fps has emerged as a powerful analytical tool for studying the existence and uniqueness of solutions to various types of functional, integral, and differential equations. In recent years, the incorporation of fractional derivatives into mathematical models has attracted significant interest because of their capacity to describe memory and hereditary properties of various complex systems in physics, biology, engineering, and finance. Fractional differential equations (FDEs) provide a natural framework for modeling such phenomena, yet finding their exact analytical solutions often poses significant challenges.
This section employs the fp theorems obtained earlier in the preceding sections to investigate the existence and uniqueness of solutions for a certain class of FDEs. By constructing a suitable operator associated with the given fractional problem and defining an appropriate -mss, we demonstrate that the operator satisfies the required contractive condition. Consequently, the solution of the FDE is obtained as the fp of this operator.
Through this method, the effectiveness of fp theory is clearly shown in handling nonlinear fractional systems but also provides a unifying framework that can be extended to various boundary value problems and integral formulations involving fractional derivatives. Thus, the following example/application illustrates the practical significance of our theoretical results in solving real-world fractional models.
Let Consider the fractional differential equation:
where
- denotes a fractional derivative,
- is a given continuous,
- is the unknown function to be determined.The fractional derivative (with ) leads to the standard Volterra representationwhere and are constants determined by the two boundary conditions, and represents the Gamma function. From we get SoUse the second (nonlocal) boundary condition to determine ComputeComputeEvaluate the double integral by Fubini:Multiply by and we getThus,Hence,Substituting the value of in the Equation (19), we haveThus,where the Green’s function is:
For
For
Let with the sup norm . Define by
for all and by Then () is an -complete -ms with and
Theorem 4.
Let () be an -complete -ms endowed with the directed graph , where Let us assume that the following conditions are satisfied:
(i) the function is continuous in t and and Lipschitz in that is, for all and
for some constant
(ii) Let be the Green kernel. Set
Assume (i.e., ). Then the boundary-value problem (18) has a unique solution. Moreover the solution is the unique fp of the operator
and the Picard iterates converge exponentially to this solution for any initial
Proof.
The operator ℜ is edge-preserving relative to this graph because every ordered pair is an edge: for any and also trivially true since For we have
By the assumption (i), we have
Taking the supremum over we have
By hypothesis (ii), we have
Thus
Now choose any , then trivially holds because Since So
Since we have so
Thus, all the conditions of Theorem 2 are satisfied, and the operator has unique fp which is a solution of the boundary-value problem (18). □
Example 5.
Let Consider the fractional boundary-value problem
where denotes the fractional derivative of order and is the unknown function. Define
The function is continuous since
- is continuous;
- is continuous on ;
- sums and scalar multiples of continuous functions are continuous.
Moreover, for all and
Thus, g is Lipschitz continuous in the second variable with Lipschitz constant
Hence, assumption (i) of Theorem 4 is satisfied. As derived in the theorem, the solution of problem satisfies the equivalent integral equation
where the Green’s function is:
For
For
Since the Gamma value satisfies
The function is continuous on the compact set Therefore,
A direct estimate yields
Now define
Therefore, assumption (ii) holds. Let endowed with the -metric
Define by Then () is an -complete -ms with and All hypotheses of Theorem 4 are satisfied. Hence, the operator defined by
admits a unique fp , which is the unique solution of the fractional boundary-value problem (24).
Applications to Integral Equations
This section demonstrates the use of the fp theorems obtained earlier to solve specific integral equations. In particular, we apply the developed theorems to a nonlinear mixed Volterra–Fredholm integral equation and demonstrate that the existence and uniqueness of its solution can be guaranteed within the framework of -mss. This application emphasizes the robustness and broad utility of the given fp results in dealing with nonlinear integral problems.
Consider the nonlinear mixed Volterra–Fredholm integral equation
where
- is a given continuous function;
- are continuous kernels;
- denotes the unknown function to be solved.
Assume the following hold.
(cond1): the kernals and are Lipschitz continuous in the third argument; that is,
there exist such that, for all and
(cond2): the kernal functions are nondecreasing; i.e., if then
(cond3):
(cond4): there exists some such that
for all where
(cond5): the Picard sequence {} is uniformly bounded in by some and
Theorem 5.
Under assumptions (cond1)–(cond6) the nonlinear mixed Volterra–Fredholm integral Equation (25) has a unique solution
Proof.
Let be equipped with the -metric given by
and by
then form an -complete -ms with for and . Let G be the graph with vertices X and edges
Then G is the pointwise order graph which is a directed graph.
For any continuity of g and K (and boundedness on compact domain) imply Now for with () Then for all Thus, by the assumption (cond2), we have
for all Hence,
so Thus, ℜ is edge-preserving. Now for any with (), we get for
Since we have
Evaluating the supremum over the interval gives
holds for By the assumption (cond5), there exists with Define
Since ℜ is edge-preserving, so
By (cond5), the sequence {} is uniformly bounded and there exists such that
Taking the limit and supremum, we have
By assumption (cond3), From (cond5), we have
Hence,
Therefore, condition (ii) of Theorem 2 is satisfied. Moreover, since ℜ is Lipschitz in sup-norm, it is G-continuous. Also, if uniformly and ( then for all so ( Hence, condition (iii) holds. Thus, ℜ admits a unique fp, representing the unique solution of the nonlinear mixed Volterra–Fredholm integral Equation (25). □
These examples demonstrate that the abstract fp results developed in this work are not only of theoretical value but also directly applicable to mathematical models involving memory effects and hereditary phenomena, such as those described by fractional differential equations. The ability to reformulate such equations as operator equations in a suitable -ms provides a systematic approach for proving the existence and uniqueness of solutions. This framework can be readily extended to other models in applied mathematics, including reaction–diffusion systems, population dynamics, and viscoelastic materials.
Example 6.
Consider the nonlinear mixed Volterra–Fredholm integral equation
Here,
For all we have
Thus,
Thus, condition (cond1) is satisfied. Since both kernels and are linear and increasing, we have
implies
Thus, condition (cond2) is satisfied. Since, the function is continuous on . Moreover,
Hence, the condition (cond3) holds. Choose Then,
Thus,
and (cond4) is satisfied. Define the Picard sequence
Taking the supremum norm, we obtain
By induction, it follows that
Hence, the Picard sequence is uniformly bounded with Moreover,
and
Since
so condition (cond5) is satisfied. All assumptions (cond1)–(cond5) of the theorem are satisfied. Therefore, the nonlinear mixed Volterra–Fredholm integral Equation (25) admits a unique solution
5. Conclusions
In this study, we introduced the notion of graphic rational contractions and interpolative Ćirić–Reich–Rus-type cyclic contractions in the setting of -mss and obtained some new fp theorems for these generalized contractions. Unlike previous studies, which considered the Banach contraction principle in -mss, our work explores graphic and interpolative cyclic contractions in -mss for the first time. Furthermore, we provide a fp approach for solving mixed Volterra–Fredholm integral equations in this framework, and our graphic rational contraction theorem serves as a generalization of Banach contraction principle in -ms, offering broader applicability under more flexible conditions.
Importantly, our theoretical contributions are broad and flexible: under certain natural simplifications, the developed framework recovers classical fp results, including well-established theorems in standard -mss, b-mss, and classical mss. This highlights both the generality and foundational relevance of our approach.
To demonstrate the significance and applicability of the results, we provided illustrative examples and validated the practical utility of the derived theorems through their successful application in solving fractional differential equations and mixed Volterra–Fredholm integral equations. Overall, this study not only advances the theory of generalized mss but also offers tools with tangible applications in mathematical analysis and related fields.
Author Contributions
Conceptualization, M.G.A.; Methodology, M.G.A. and J.A.; Formal analysis, M.G.A. and J.A.; Investigation, M.G.A. and J.A.; Writing—original draft, J.A.; Writing—review & editing, M.G.A. and J.A.; Visualization, M.G.A.; Supervision, J.A.; Project administration, J.A.; Funding acquisition, M.G.A. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Frechet, M. Sur quelques points du calcul fonctionnel. Rend. Circ. Mat. Palermo 1906, 22, 1–72. [Google Scholar] [CrossRef] [Scilit]
- Bakhtin, I.A. The contraction mapping principle in almost metric spaces. Funct. Anal. 1989, 30, 26–37. [Google Scholar]
- Czerwik, S. Contraction mappings in b-metric spaces. Acta Math. Inform. Univ. Ostra. 1993, 1, 5–11. [Google Scholar]
- Fagin, R.; Kumar, R.; Sivakumar, D. Comparing top k lists. SIAM J. Discret. Math. 2003, 17, 134–160. [Google Scholar] [CrossRef] [Scilit]
- Khamsi, M.A.; Hussain, N. KKM mappings in metric type spaces. Nonlinear Anal. 2010, 7, 3123–3129. [Google Scholar] [CrossRef] [Scilit]
- Branciari, A. A fixed point theorem of Banach-Caccioppoli type on a class of generalized metric spaces. Publ. Math. Debr. 2000, 57, 31–37. [Google Scholar] [CrossRef] [Scilit]
- Jleli, M.; Samet, B. On a new generalization of metric spaces. J. Fixed Point Theory Appl. 2018, 2018, 128. [Google Scholar] [CrossRef] [Scilit]
- Panda, S.K.; Abdeljawad, T.; Ravichandran, C. Novel fixed point approach to Atangana-Baleanu fractional and Lp-Fredholm integral equations. Alex. Eng. J. 2020, 59, 1959–1970. [Google Scholar] [CrossRef] [Scilit]
- Albargi, A.H.; Ahmad, J. On the existence of solutions for Atangana–Baleanu type fractional integral equations via fixed point theorems in extended -metric spaces. Fractal Fract. 2026, 10, 128. [Google Scholar] [CrossRef] [Scilit]
- Banach, S. Sur les operations dans les ensembles abstraits et leur applications aux equations integrales. Fundam. Math. 1922, 3, 133–181. [Google Scholar] [CrossRef] [Scilit]
- Kannan, R. Some results on fixed points. Bull. Calcutta Math. Soc. 1968, 60, 71–76. [Google Scholar]
- Reich, S. Kannan’s fixed point theorem. Boll. Un. Mat. Ital. 1971, 4, 1–11. [Google Scholar]
- Jachymski, J. The contraction principle for mappings on a metric space with a graph. Proc. Amer. Math. Soc. 2008, 136, 1359–1373. [Google Scholar] [CrossRef] [Scilit]
- Bojor, F. Fixed points of Kannan mappings in metric spaces endowed with a graph. An. St. Univ. Ovidius Constanta 2012, 20, 31–40. [Google Scholar] [CrossRef] [Scilit]
- Acar, Ö.; Altun, A. New fixed point results via a graph structure. Mathematics 2021, 9, 1013. [Google Scholar] [CrossRef] [Scilit]
- Choudhury, B.S. Common fixed point results in metric spaces endowed with a directed graph. J. Nonlinear Convex Anal. 2013, 14, 1–12. [Google Scholar]
- Kirk, W.A.; Srinivasan, P.S.; Veeramani, P. Fixed points for mappings satisfying cyclical contractive conditions. Fixed Point Theory 2003, 4, 79–89. [Google Scholar]
- Karapınar, E. Revisiting the Kannan type contractions via interpolation. Adv. Theory Nonlinear Anal. Appl. 2018, 2, 85–87. [Google Scholar] [CrossRef] [Scilit]
- Karapınar, E.; Agarwal, R.P.; Aydi, H. Interpolative Reich-Rus-Ćiric type contractions on partial metric spaces. Mathematics 2018, 6, 256. [Google Scholar] [CrossRef] [Scilit]
- Thangaraj, C.; Easwaramoorthy, D.; Selmi, B.; Chamola, B.P. Generation of fractals via iterated function system of Kannan contractions in controlled metric space. Math. Comput. Simul. 2024, 222, 188–198. [Google Scholar] [CrossRef] [Scilit]
- Hussain, A.; Kanwal, T. Existence and uniqueness for a neutral differential problem with unbounded delay via fixed point results. Trans. Razmadze Math. Inst. 2018, 172, 481–490. [Google Scholar] [CrossRef] [Scilit]
- Al-Mazrooei, A.E.; Ahmad, J. Fixed point theorems for rational contractions in -metric spaces. J. Mat. Anal. 2019, 10, 79–86. [Google Scholar]
- Alnaser, L.A.; Ahmad, J.; Lateef, D.; Fouad, H.A. New fixed point theorems with applications to non-linear neutral differential equations. Symmetry 2019, 11, 602. [Google Scholar] [CrossRef] [Scilit]
- Hussain, A.; Jarad, F.; Karapinar, E. A study of symmetric contractions with an application to generalized fractional differential equations. Adv. Differ. Equ. 2021, 2021, 300. [Google Scholar] [CrossRef] [Scilit]
- Hussain, A. Fractional convex type contraction with solution of fractional differential equation. AIMS Math. 2020, 5, 5364–5380. [Google Scholar] [CrossRef] [Scilit]
- Hussain, A. Solution of fractional differential equations utilizing symmetric contraction. J. Math. 2021, 2021, 5510971. [Google Scholar] [CrossRef] [Scilit]
- Mitrovic, Z.; Aydi, H.; Hussain, N.; Mukheimer, A. Reich, Jungck, and Berinde common fixed point results on -metric spaces and an application. Mathematics 2019, 7, 2–11. [Google Scholar] [CrossRef] [Scilit]
- Al-Mezel, S.A.; Ahmad, J.; Marino, G. Fixed point theorems for generalized (αβ-ψ)-contractions in -metric spaces with applications. Mathematics 2020, 8, 584. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.