Article

Inverse Firefly-Based Search Algorithms for Multi-Target Search Problem

1
LabSTIC Laboratory, Department of Computer Science, 8 Mai 1945 University, P.O. Box 401, Guelma 24000, Algeria
2
CNR, National Research Council of Italy, Institute for High Performance Computing and Networking (ICAR), Via P. Bucci 8/9C, 87036 Rende, Italy
3
Department of Computer Science, 8 Mai 1945 University, P.O. Box 401, Guelma 24000, Algeria
4
Department of Informatics, Modeling, Electronics, and Systems, University of Calabria, 87036 Rende, Italy
*
Authors to whom correspondence should be addressed.
Big Data Cogn. Comput. 2024, 8(2), 18; https://doi.org/10.3390/bdcc8020018
Submission received: 1 November 2023 / Revised: 12 February 2024 / Accepted: 14 February 2024 / Published: 19 February 2024
(This article belongs to the Special Issue Big Data and Cognitive Computing in 2023)

Abstract

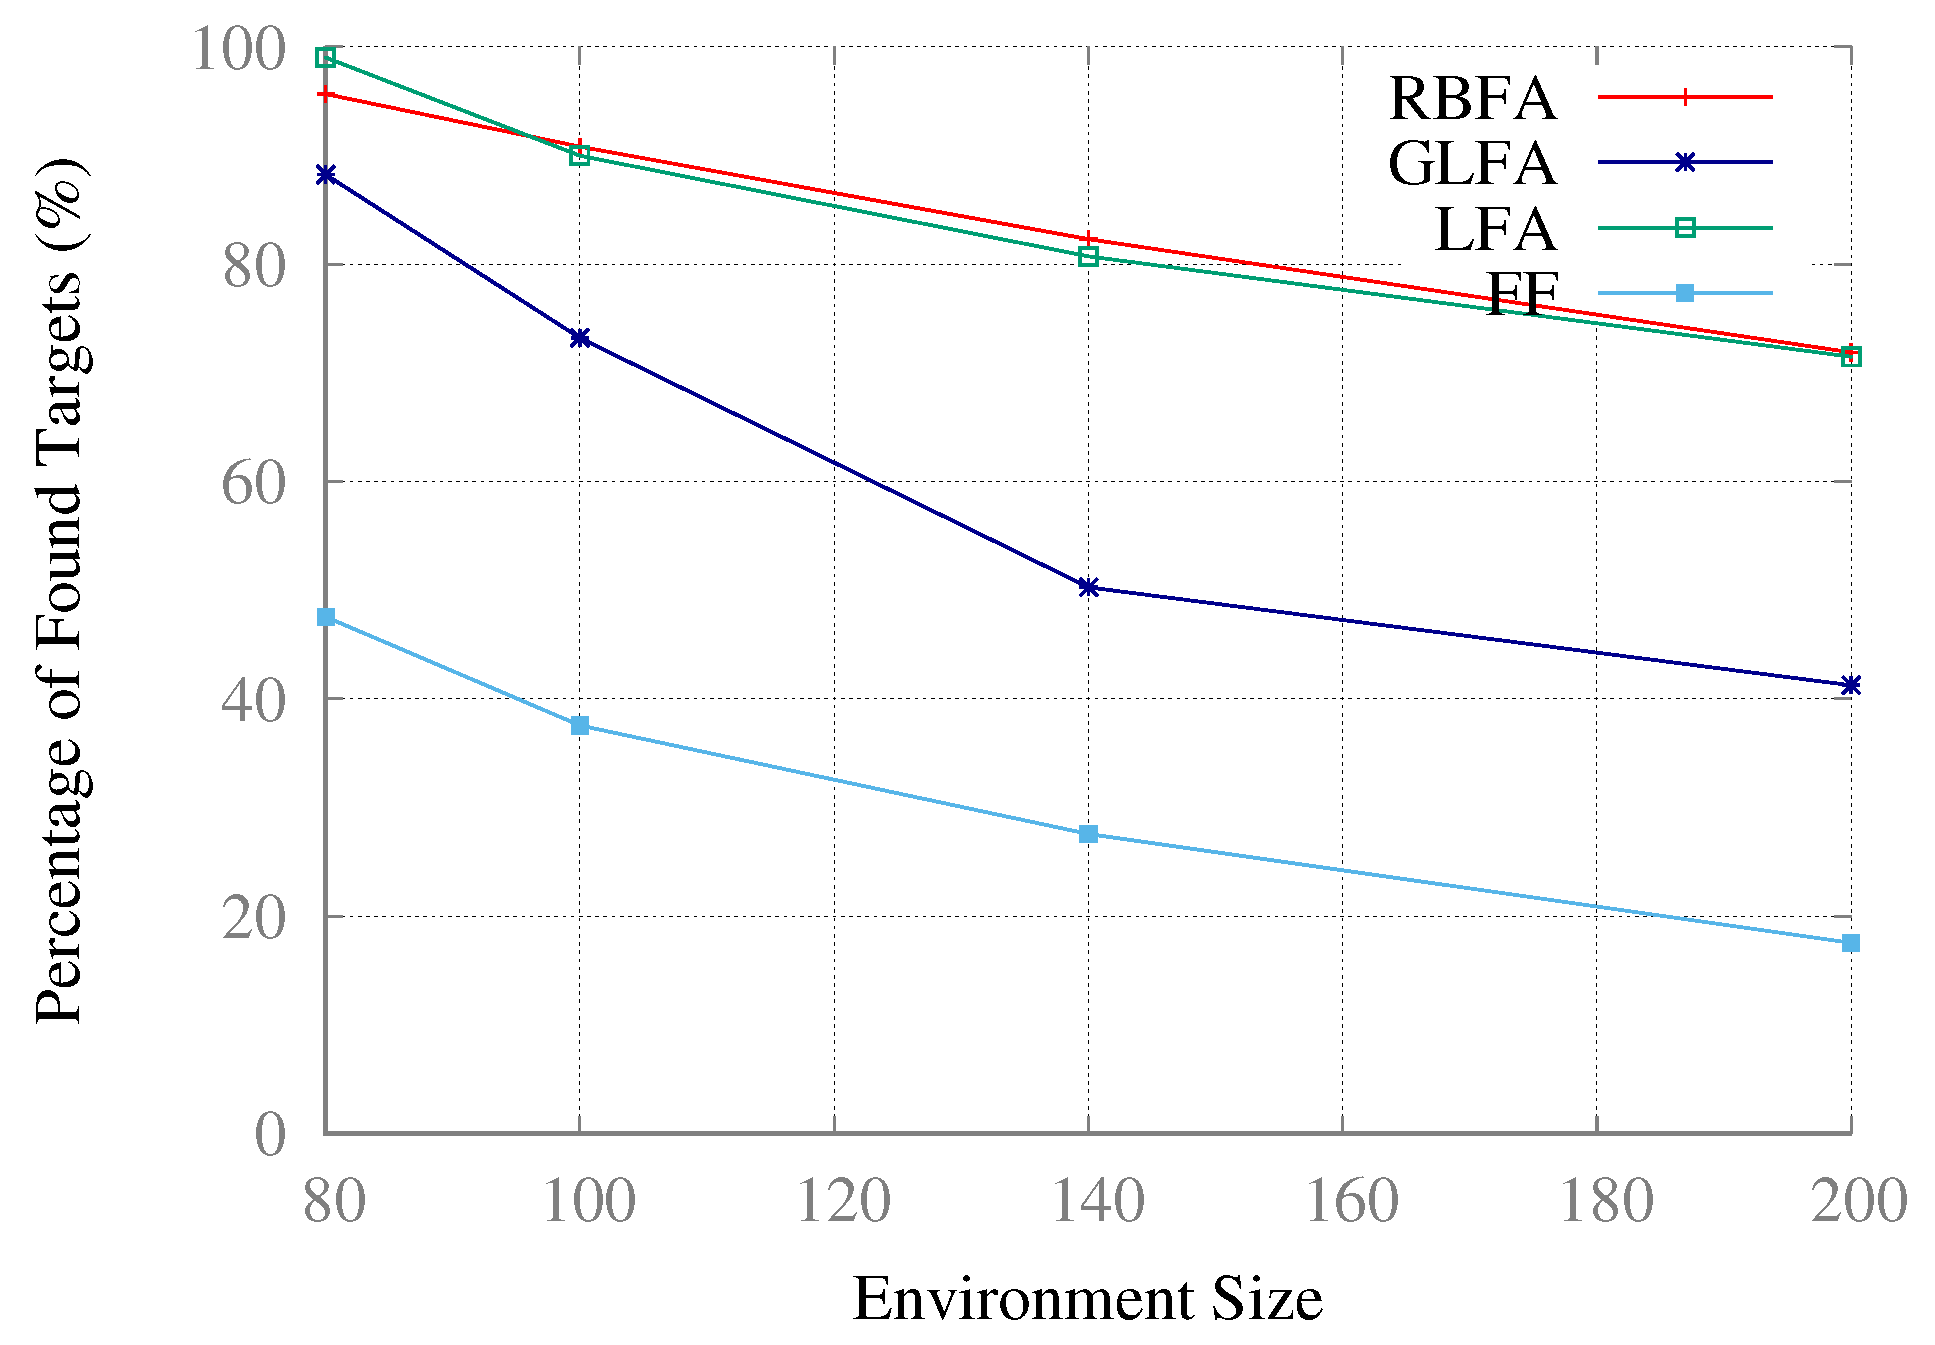
Efficiently searching for multiple targets in complex environments with limited perception and computational capabilities is challenging for multiple robots, which can coordinate their actions indirectly through their environment. In this context, swarm intelligence has been a source of inspiration for addressing multi-target search problems in the literature. So far, several algorithms have been proposed for solving such a problem, and in this study, we propose two novel multi-target search algorithms inspired by the Firefly algorithm. Unlike the conventional Firefly algorithm, where light is an attractor, light represents a negative effect in our proposed algorithms. Upon discovering targets, robots emit light to repel other robots from that region. This repulsive behavior is intended to achieve several objectives: (1) partitioning the search space among different robots, (2) expanding the search region by avoiding areas already explored, and (3) preventing congestion among robots. The proposed algorithms, named Global Lawnmower Firefly Algorithm (GLFA) and Random Bounce Firefly Algorithm (RBFA), integrate inverse light-based behavior with two random walks: random bounce and global lawnmower. These algorithms were implemented and evaluated using the ArGOS simulator, demonstrating promising performance compared to existing approaches.
Keywords: swarm intelligence; swarm robotics; multi-targets search problem; firefly algorithm; random bounce; global lawnmower swarm intelligence; swarm robotics; multi-targets search problem; firefly algorithm; random bounce; global lawnmower