


Abstract
This study examined the effects of robot speed, number, and spatial orientation on operator stress, mental workload, attention, and excitement during human–robot collaboration. As collaborative robots (cobots) become increasingly prevalent in modern manufacturing, operator safety concerns persist. Despite Industry 5.0’s focus on human-centered production, the impact of robot configuration on operators’ cognitive and emotional states remains underexplored. Thirty participants completed eight sessions of a Lego block stacking task using a mixed-factor (3 × 2 × 2) within-subjects design that varied robot speed (slow, fast, or mixed), robot number (one or two), and left–right spatial orientation. Physiological data were collected continuously via an Empatica E4 wristband and analyzed using linear mixed models; subjective data were collected via a post-session questionnaire and analyzed using non-parametric tests. Slower robot speeds reduced stress, workload, attention, and excitement relative to higher speeds. Two robots increased stress, mental workload, attention, and excitement relative to one robot, with consistent elevations in electrodermal activity, shorter inter-beat intervals, and lower skin temperature confirming sympathetic arousal. The fast two-robot condition produced the highest subjective demand across all measures. Notably, one robot at fast speed and two robots at slow speed produced statistically comparable subjective workload, suggesting both configurations offer productive alternatives with manageable operator strain. Robot spatial orientation did not significantly affect any outcome measure. These findings suggest that, under the conditions of this laboratory paradigm, a configuration of one robot at fast speed may offer a favorable balance of workload and engagement for safe and effective collaboration, with two robots at slow speed as a viable secondary alternative; direct objective productivity data were not collected, and these recommendations should be validated against task throughput in future work. Design implications for collaborative workstations are discussed.
1. Introduction
The development of Industry 4.0 enabled the introduction of collaborative robots (cobots) into manufacturing processes [1,2,3]. Cobots are designed as safer and more efficient alternatives to traditional automation, particularly for repetitive tasks requiring human dexterity and cognition [1]. By combining operator flexibility with robotic efficiency, cobots allow operators to focus on higher-level tasks while robots perform simple actions. This human–robot collaboration improves productivity and cost efficiency [4]. However, increased physical proximity raises concerns regarding cognitive and emotional impacts on operators [1,5].
Although cobots improve physical safety, research addressing broader human factors in human–robot collaboration remains limited. Existing work prioritizes safety [6] while giving less attention to operator experience [7], even with the emergence of Industry 5.0. In particular, the effects of robot configuration—such as number, speed, and spatial orientation—on mental workload and stress remain underexplored.
Prior research suggests that robot motion characteristics influence operator stress and workload. Higher robot speeds, closer proximity, and reduced motion predictability have been associated with increased stress, anxiety, and mental workload [8,9,10,11,12,13,14]. Some studies also show that advance notice of robot motion or predictable trajectories can reduce operator strain [8,10]. Additionally, the use of multiple robots has been associated with increased emotional arousal and perceived task difficulty due to higher monitoring demands [15]. Other work highlights the role of motion-related and interaction factors in shaping human comfort and performance during collaboration [16,17,18]. Rückert et al. [17] specifically found that the use of the dominant hand showed an improvement in collaborative assembly. These studies suggest that robot behavior, reliability, and interaction design can significantly influence operator engagement, trust, and cognitive state [19].
However, some studies report minimal or even positive effects of cobot collaboration. Experiments comparing human–robot and human–human collaboration found no significant increase in operator stress when working with cobots [20,21]. Other studies report reduced workload, fewer human errors, and improved task performance during cobot-assisted work [22,23]. Additionally, robot proximity alone does not always influence stress responses [24].
These mixed findings indicate a need for additional empirical research on stress and workload in human–robot collaboration. Differences across studies likely reflect variations in robot characteristics, task complexity, measurement methods, and participant familiarity with robots. Several robot configurations also remain understudied, particularly robot number and left–right spatial orientation. This study examines how robot speed, number, and orientation influence operator stress and mental workload during collaborative tasks. It focuses on these variables because they represent foundational interaction characteristics that directly influence human perceptual, cognitive, and affective responses during human–robot collaboration. Prior work has shown that robot speed affects perceived predictability, time pressure, and arousal; robot number increases attentional demand and monitoring requirements; and robot orientation shapes spatial compatibility and motor planning demands. These factors operate at a low level of interaction and can be systematically manipulated by system designers, making them particularly suitable for controlled experimental investigation. This study does not aim to replicate full-scale industrial workcells, but rather to examine how fundamental robot configuration variables affect operator stress and workload in human-centered collaborative contexts emphasized by Industry 5.0. Accordingly, the following research questions are posed:
- How does variation in speed, robot number, and robot orientation affect the stress, mental workload, attention, and excitement of human operators of collaborative robots?
- Which combination of speed, robot number, and robot orientation causes the lowest levels of negative emotions and highest productivity?
Building on prior literature on stress, mental workload, and emotional arousal in human–robot collaboration, workload, attention, excitement, and stress were selected as key dependent variables. Workload captures cognitive demand, attention reflects task-focused processing and engagement, excitement indexes the arousal dimension of emotional response, and stress provides a direct measure of negative affect and psychological strain. Collectively, these measures provide a comprehensive assessment of operator cognitive, emotional, and stress-related states during collaborative tasks, allowing evaluation of how robot number, speed, and orientation influence both the mental and affective experiences of human operators.
The following hypotheses are proposed:
H1:
High speed will cause higher stress, mental workload, attention, and excitement than low speed.
H2:
Two robots will cause higher stress, mental workload, attention, and excitement than one robot, due to increased supervisory and coordination demands.
H3:
Focus on the left-hand side will cause higher stress, mental workload, attention, and excitement than focus on the right-hand side.
H4:
Two robots and slow speed will result in the most efficient tradeoff between productivity and emotional factors.
2. Methods
2.1. Participants
The study consisted of 30 participants (14 female), aged 18–48 (average age 24), from a college community. The participants were primarily students from the computer science and engineering departments. Twenty-nine participants were right-handed and one participant was left-handed. No participants had interacted with collaborative robots previously. The participants were recruited via email flyers and introductory course pools. Participants received $10 or course credit for completing the study. The study was reviewed and approved by the Institutional Review Board (IRB) at the authors’ institution (Approval No. 2023-03-001).
2.2. Study Design
The experiment was a mixed-factor (3 × 2 × 2) design, using within-subject comparison. The independent variables were robot number, robot speed, and robot orientation. The three independent variables were mixed into eight sessions, shown in Table 1. Session order was randomized for each participant.
Table 1.
Session configurations.
The dependent variables were stress, mental workload, attention, robot predictability, and excitement. Stress refers to exposure to stimuli appraised as harmful or challenging beyond the individual’s coping capacity [25]. Mental workload is defined as the amount of cognitive effort required by an individual to perform a task [26]. Attention refers to the allocation of cognitive resources to process task-relevant information, including sustained focus and selective processing of stimuli [27]. Robot predictability is defined as the degree to which an operator can anticipate a robot’s actions and movement patterns [28]. Excitement is defined as an affective state with a combination of high pleasure and high arousal [29]. These variables capture cognitive, emotional, and stress-related dimensions of operator experience during collaborative tasks.
2.3. Robot Description
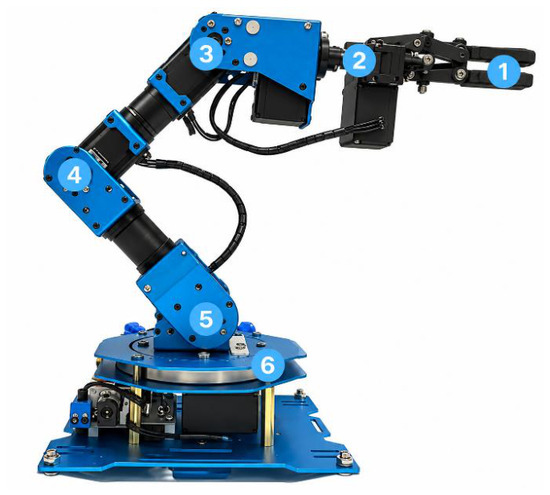
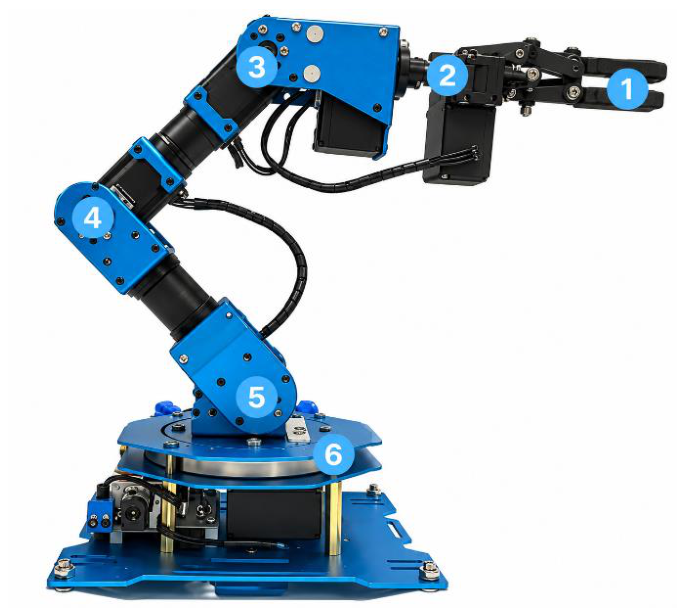
Two HiWonder (Shenzhen Hiwonder Technology Co., Ltd.; Shenzhen; China) xArm 1s25 robotic arms were used, each with six degrees of freedom. Figure 1 shows the robot with joints labeled. Movement scripts were programmed via predefined action files, specifying joint positions and movement duration. The fast condition increased movement speed by 40% relative to the slow condition. Absolute joint velocities (°/s) or per-cycle movement duration (s) for the slow and fast conditions were taken from the action-file logs; e.g., the slow condition completed the six-phase pick-and-place cycle in approximately X s and the fast condition completed it in approximately Y s.
Figure 1.
HiWonder xArm 1s25 with labeled joints. Joint 6 rotated the robot, joints 3–5 controlled vertical movement, joint 2 rotated the hand, and joint 1 opened and closed the hand.
Picking up a Lego block consisted of six movements. The first moved the cobot to the location of the relevant Lego block. Then, the robot bent to hover over the block. The cobot closed its hand on the block and then lifted it directly upwards. The cobot moved to the location of the basket, then opened its hand to drop the block. This six-phase trajectory—move to block location, lower/hover over block, close hand, lift vertically, move to basket, open hand—was identical across all eight session types; only movement duration (i.e., speed) varied by condition.
2.4. Experiment Design
Experiment Setting
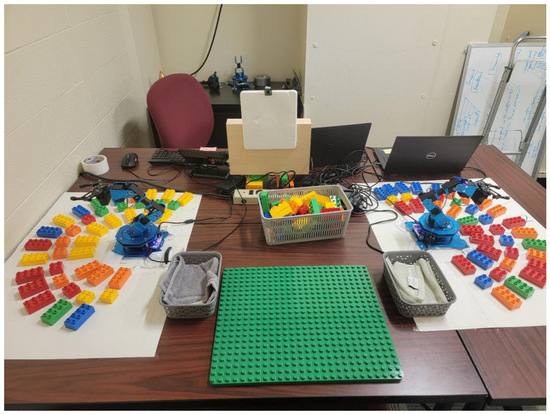
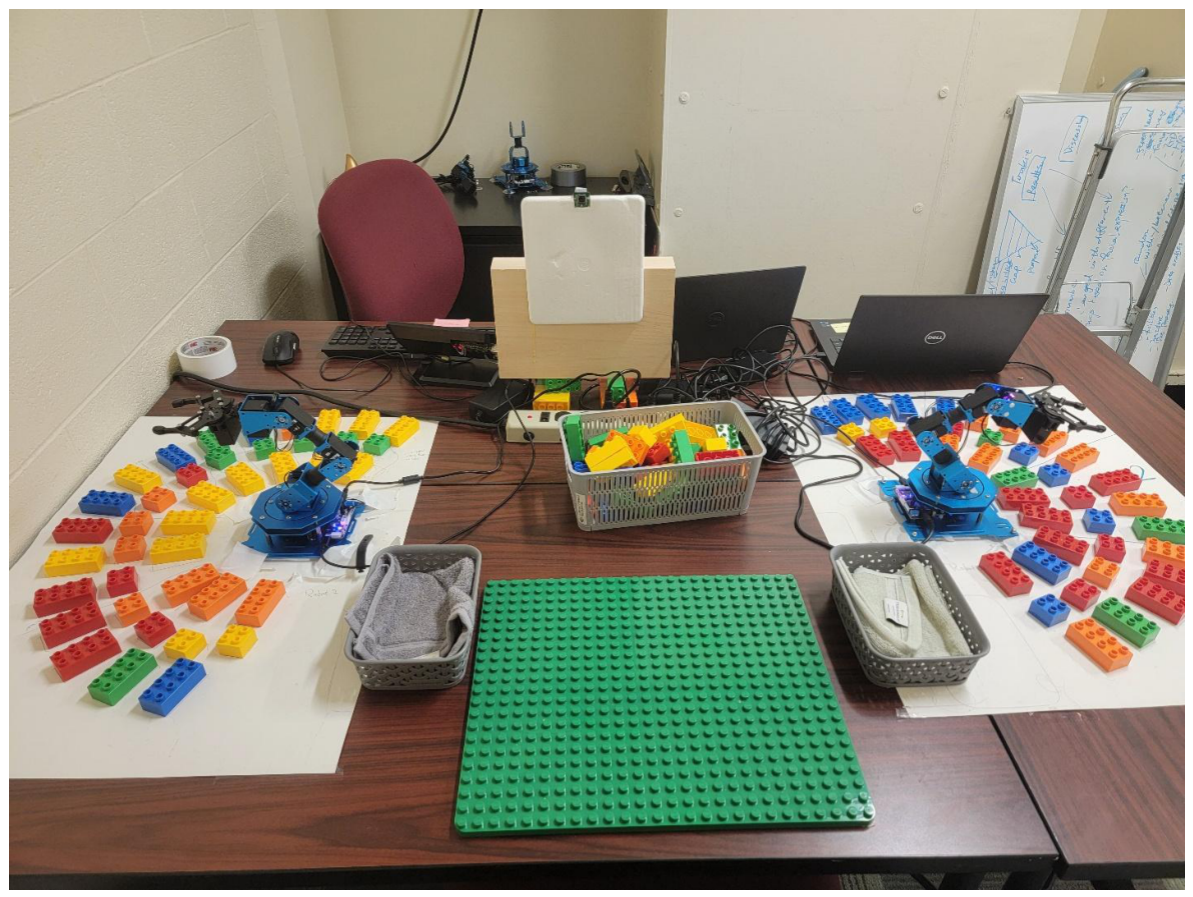
The lab was set up as an office with desk tables and comfortable office chairs. Small robot arms were chosen to limit potential intimidation from large machinery. The task utilized Lego blocks due to their prevalence as a simple building system. Figure 2 shows the setting of the experiment.
Figure 2.
The setup of the experiment in the laboratory environment. The participant sat on one side of a table with a Lego board in front of them and one robot on their right and left sides. Approximate distance (cm/m) between the participant’s seated position and each robot base, and between the participant and the Lego board/basket. Each of the two robots had a semi-circle of Lego blocks in front of them. Small plastic baskets were used for block delivery. The researcher sat on the opposite side of the table to control the robots and the cameras.
The task emulated a simple factory process that leveraged human dexterity and robotic delivery while maintaining a non-industrial environment. It involved the robot(s) delivering the Lego blocks to the participant one-by-one. The robots followed a pre-programmed action file. The participant used the Lego blocks to make stacks of 5 blocks on the Lego board, and was told to stack the two sizes of Lego block (4-prong or 8-prong) homogeneously. The participant completed the block stacking while the robots were consistently delivering them blocks. The total number of blocks delivered during each 270-s session was recorded to determine whether the count remained constant or varied across different speed and robot-number conditions. The simple task minimized stress from task complexity and allowed clearer isolation of the dependent variables.
The task was time-bounded rather than completion-bounded: each session ran for a fixed 270 s regardless of how many five-block stacks the participant completed within that window, so ‘task completion’ in the sense of a fixed target quantity was not defined. The dependent measures therefore reflect operator state during continuous engagement with an ongoing task rather than performance against a discrete goal. Each robot delivered blocks at a constant pace within its assigned speed condition; however, because two robots delivered blocks in parallel, the two-robot conditions produced a higher combined block-delivery rate than the one-robot conditions.
2.5. Data Collection
2.5.1. Subjective Measurements
A questionnaire was completed to assess subjective variables. The first section of the questionnaire asked participants to rank their stress, attention (how attentive to the task they were), and excitement on a scale from 1 (low) to 5 (high). Participants also rated robot movement predictability during the session from 1 (unpredictable) to 5 (predictable). They were also asked to state the cause of stress, if any.
The second section assessed mental workload using questions from the NASA Task Load Index [30]. The participants responded to each question on a scale from 1 to 20.
In baseline data collection, the participant was questioned only about stress, how attentive to tasks they currently felt, and excitement.
2.5.2. Physiological Measurements
An Empatica E4 wristband (Empatica Inc., Boston, MA, USA) was used to collect continuous physiological data. The measures taken include electrodermal activity (EDA), skin temperature, heart rate (HR), blood-volume pulse (BVP), inter-beat interval (IBI), and acceleration. These signals were acquired at the device’s standard rates: EDA and skin temperature at 4 Hz, BVP at 64 Hz, HR derived at 1 Hz, and 3-axis acceleration at 32 Hz.
EDA measures emotional stimulation by sending pulses to measure sweat level on the skin. The type of emotional stimulation is inferred based on the situation. In this experiment, it was inferred that it relates to stress or excitement level. However, due to the ambiguity of the type of emotional stimulation, this was confirmed through the other data modes. Two measures were extracted from EDA: skin-conductance response (SCR) and skin-conductance level (SCL). SCR measures peaks at short intervals, and SCL shows the general trend over time.
The additional physiological measures provide further insight into stress level and emotional state. Skin temperature has been shown to decrease during stressful situations [31]. Heart rate increases during periods of excitement, stress, or high physical activity. BVP and IBI are related to heart rate variability, which is an indicator of autonomic variation. While decreases in HRV are often associated with stress, this relationship is complex and context-dependent, varying with task demands, individual differences, and the nature of the stressor [32,33]. Thus, physiological measures were interpreted in conjunction with subjective measurements of stress and workload to provide a robust characterization of operator state.
2.6. Procedure
The procedure involved three phases: preparation, training, and intervention. In the preparation stage, the participant was briefed on the experiment and baseline data were collected. Training consisted of three unassisted stacking trials, followed by one-minute exposure to each experimental robot condition to mitigate novelty effects. Finally, the intervention took place.
In the preparation stage, the participant read and signed informed consent. The participant was then briefed about the experiment process, including being informed how the robot would deliver blocks to them. The participant completed a 5 min guided meditation session to reduce baseline arousal. Then, a baseline questionnaire was completed and a baseline physiological measurement was taken.
In the training stage, the researcher first demonstrated block stacking for the participant. The participant then completed a one-minute cobot-assisted session for each of the eight session types, at the same robot speed and number as the corresponding formal session, before making three stacks unassisted by the cobot. Matching the pre-exposure motion parameters to each formal condition was intended specifically to habituate participants to the robot’s speed and configuration in advance, mitigating first-exposure novelty effects on stress and workload measures—a standard practice in human–robot interaction studies for separating novelty-driven responses from the condition-specific effects of interest. During the intervention, the eight session types were completed in a randomized order unique to the participant. The researcher first informed the participant of the session type, then marked the start time for the physiological measurements. Participants were informed of the upcoming robot configuration shortly before each session to reduce surprise-related startle responses and ensure participant comfort and safety during conditions involving high-speed or multi-robot motion. This information was provided only moments before task initiation to minimize anticipatory bias. The robots were configured for the session type and turned on. The session was performed for 270 s. Afterwards, the participant completed the post-session questionnaire. The total intervention lasted 40 min to one hour.
2.7. Data Processing
2.7.1. Subjective Measurements
The data was exported, and the correct session types associated with the respective responses from the participants by session number. The responses related to each session type were grouped together.
2.7.2. Physiological Measurements
The individual session data was extracted from the wristband metrics by using the start time and adding 270 s for the end time. Data were cleaned and processed in Python 3.14.7, with the use of the NeuroKit2 package for physiological signal processing [34]. NeuroKit2’s default cleaning and artifact-correction routines were applied to the EDA (Table 2) and BVP/IBI signals prior to feature extraction (Table 3). The specific cleaning parameters used the artifact-correction method applied to EDA (such as eda_clean method choice) and to BVP/IBI peak detection, any manual exclusion criteria for sessions with excessive motion artifact or signal dropout, and the number of session-participant data points, if any, excluded on this basis. As noted in Section 3, IBI-derived results should be interpreted with some caution given differential signal dropout across conditions; the quality-control criteria underlying that caveat are detailed above.
Table 2.
Electrodermal activity (EDA) metrics extracted using NeuroKit2 [34]. Physiological definitions of tonic and phasic EDA components follow Boucsein [35].
2.8. Data Analysis
Physiological measurements were analyzed using linear mixed models (LMMs) with random intercepts for the participants. Prior to modeling, each dependent variable was transformed using log1p (ln(1 + x)) to address the positive skew typical of physiological signals [35,36]. Separate single-factor models were fitted for speed, robot number, and orientation using maximum likelihood. This approach reflects the experimental design, in which certain levels were partially confounded (e.g., mixed speed and none orientation occurred only in two-robot sessions), producing empty cells in a fully crossed factorial design. Estimating factors separately therefore allowed main effects to be evaluated without introducing unidentifiable interaction terms.
Table 3.
IBI and heart rate variability (HRV) metrics extracted using NeuroKit2 [34]. Metric definitions follow standard HRV guidelines [33,37].
Two-factor analyses were additionally conducted for subsets of the data where a complete factorial design was available. For speed × robots analyses, mixed-speed trials were excluded to obtain a complete 2 × 2 design (slow vs. fast × one vs. two robots). For speed × orientation analyses, the none orientation condition was excluded. Reference levels were one (robots), slow (speed), and left (orientation). Remaining pairwise contrasts not directly represented by model coefficients (mixed vs. fast and right vs. none) were evaluated post hoc using Wald tests.
Model diagnostics included Shapiro–Wilk tests for residual normality, Breusch–Pagan tests for heteroscedasticity, and Durbin–Watson statistics for residual autocorrelation. Given the relatively large sample size (N ≈ 200 for EDA and BVP metrics), minor deviations from normality were not considered problematic for inference.
Subjective measurements were collected using a 5-point Likert scale [38] and the 20-point NASA-TLX index and were analyzed using non-parametric tests. For three-level factors (speed and orientation), Friedman tests were first applied, followed by pairwise Wilcoxon signed-rank tests when significant. For the two-level factor (robots), Wilcoxon signed-rank tests were applied directly. Where multiple observations occurred within the same condition, scores were averaged prior to analysis. All p-values were corrected using the Holm–Bonferroni procedure. Spearman correlations were computed to assess relationships among subjective measures. Results for both physiological and subjective measurements are reported at the significance threshold of p < 0.05.
3. Results
Table 4 and Table 5 show the results of the one-factor statistical analyses. Variables without any significant results were excluded. As orientation had no significant results, it is omitted from this section.
Table 4.
Wilcoxon signed-rank test results for robot number (one vs. two robots). Cells show mean (SD). W is the Wilcoxon signed-rank statistic. p-values are Holm–Bonferroni corrected. Bold indicates p < 0.05.
Table 5.
Physiological results for robot number conditions. Cells show mean (SD). β indicates the model coefficient. Bold indicates p < 0.05.
3.1. Stress Factor Identification
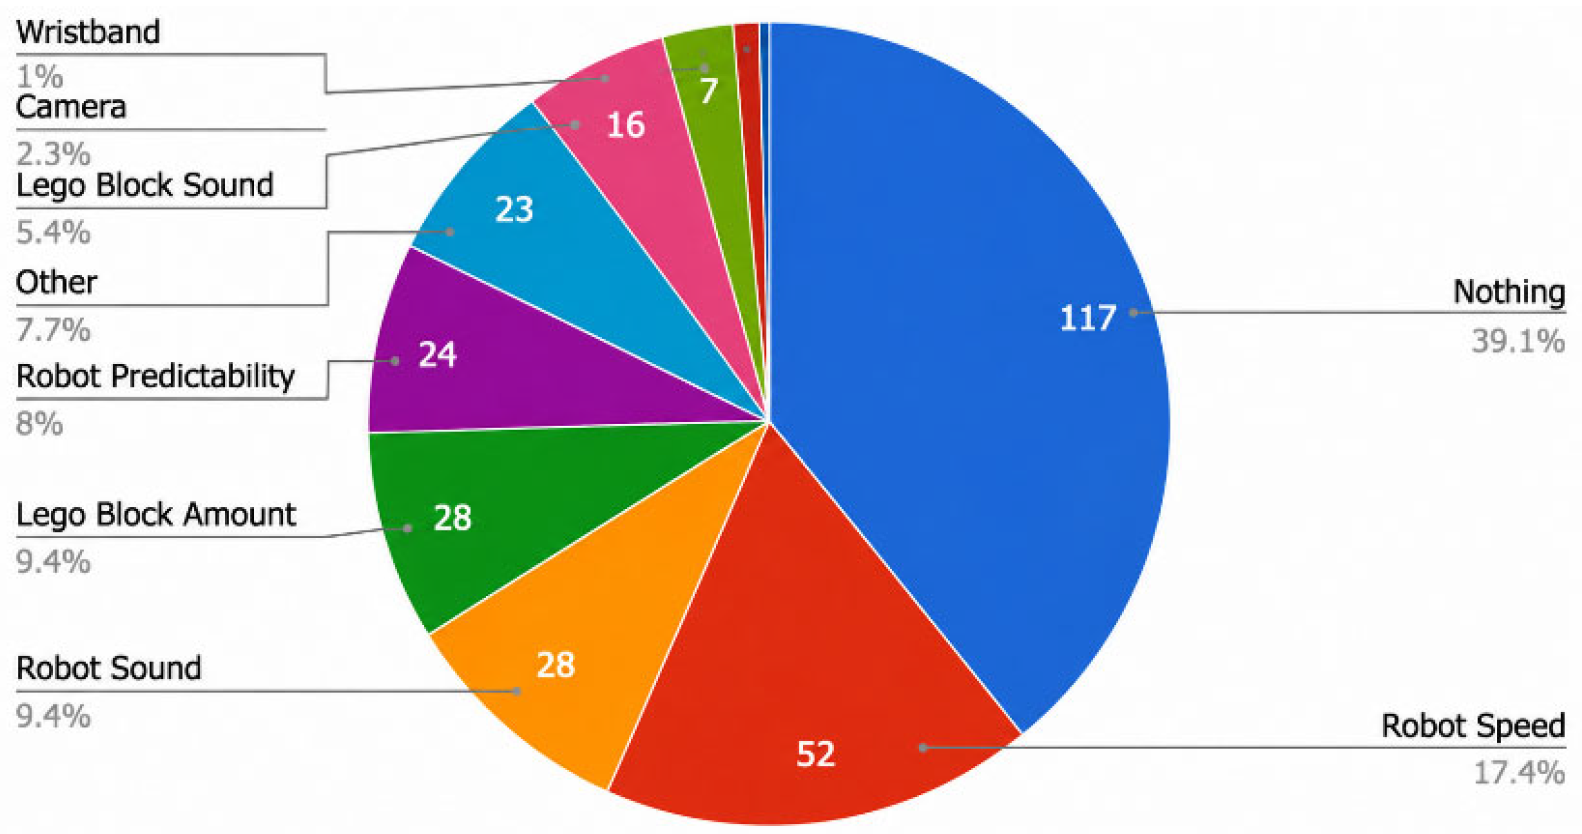
Participants who reported a stressor most frequently identified robot speed (17.4%), followed by robot sound and number of blocks (both 9.4%); the largest group of participants (39.1%) reported no dominant stressor (Figure 3). Among participants who did identify a source of stress, robot speed was therefore the most frequently cited factor, followed by robot sound and block delivery volume.
Figure 3.
Reported factors influencing participants’ perceived stress.
3.2. Correlation Table
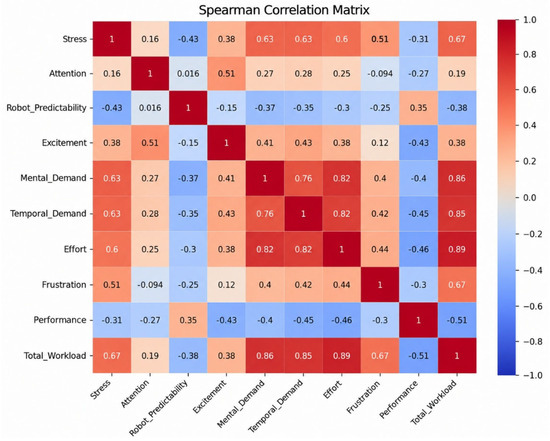
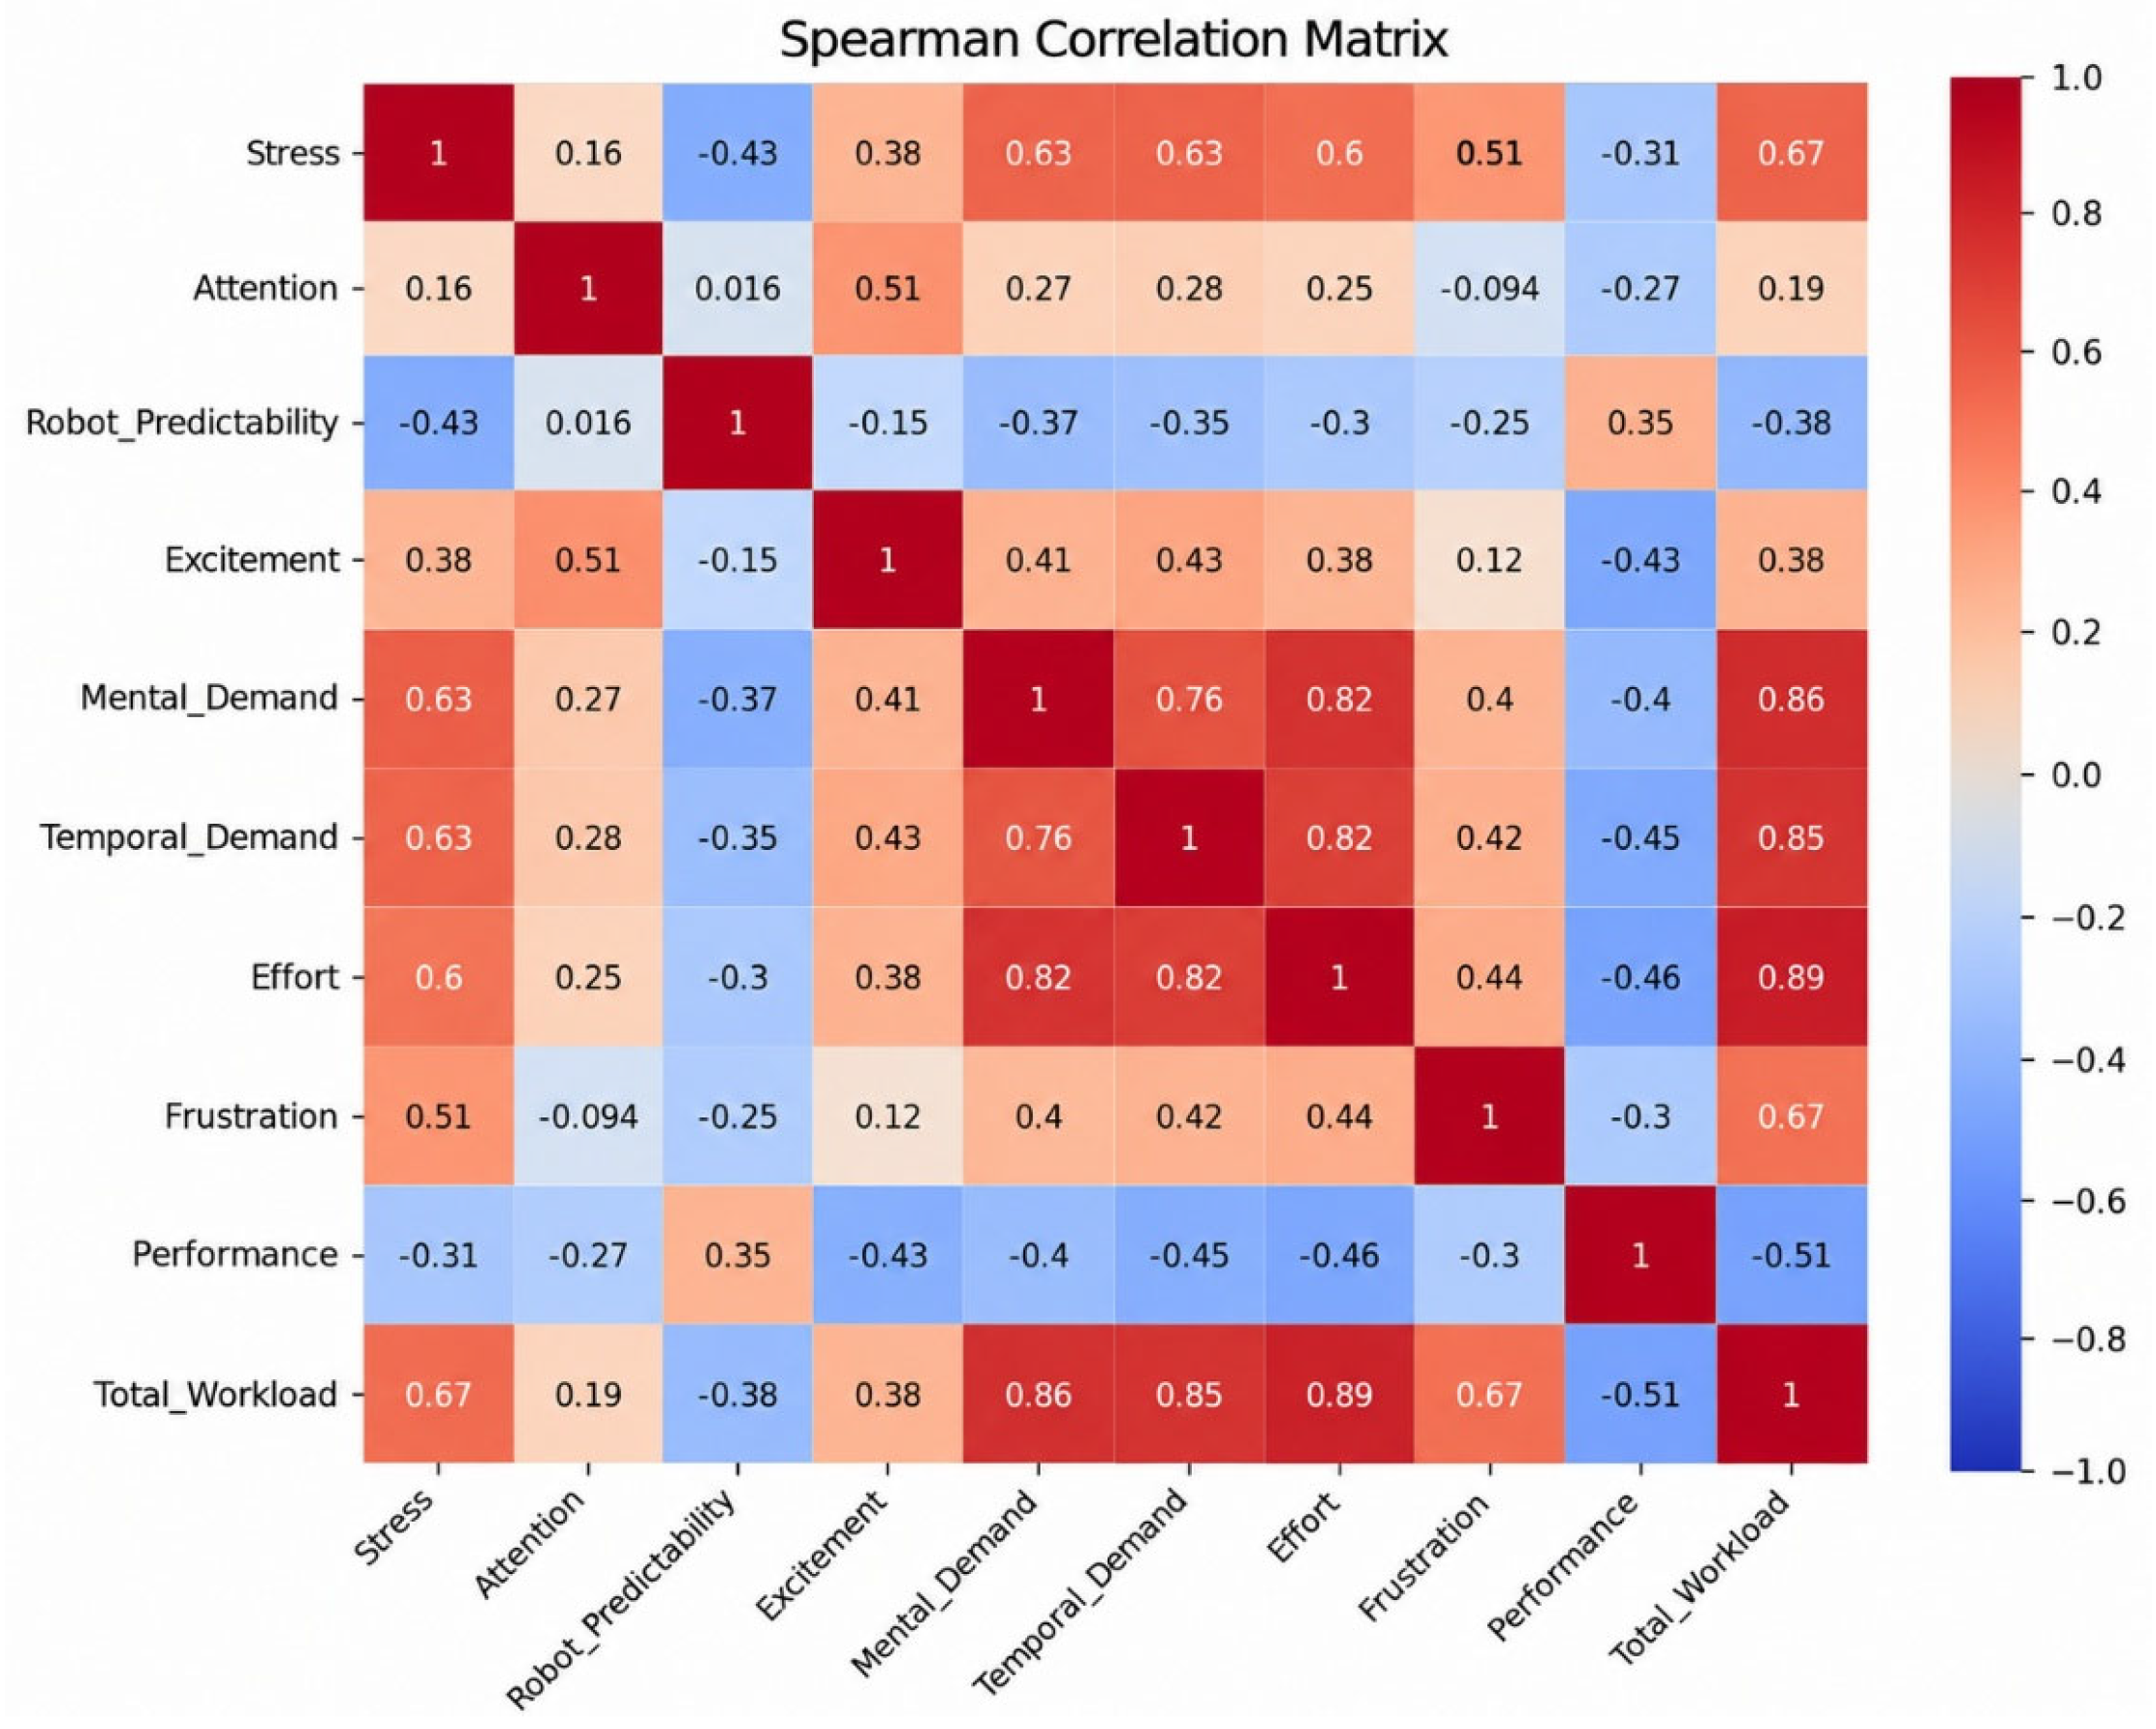
Spearman correlations among subjective measures revealed a strong cluster of workload-related variables (Figure 4 and the Supplementary table for corresponding correlation coefficients and p-values). Mental demand, temporal demand, effort, and total workload were highly intercorrelated (ρ = 0.76–0.89), indicating a common dimension of perceived task strain. Stress and frustration were moderately associated with this cluster (ρ ≈ 0.40–0.67). In contrast, perceived robot predictability showed moderate negative correlations with stress and workload (ρ ≈ −0.38 to −0.43), suggesting that more predictable robot behavior reduced perceived demands. Self-rated performance was negatively correlated with workload (ρ ≈ −0.40 to −0.51). Attention and excitement showed weaker associations with workload (ρ ≤ 0.38) but were moderately correlated with each other (ρ = 0.51), indicating task engagement rather than strain.
Figure 4.
Spearman correlation matrix among subjective measures. Warmer colors indicate positive correlations while cooler colors indicate negative correlations. Workload-related measures (mental demand, temporal demand, stress, effort, and total workload) show strong positive associations, while perceived performance is negatively associated with workload measures. See the Supplementary Materials for the corresponding correlation coefficients and p-values.
3.3. Robot Number
The number of robots produced the clearest physiological stress response across sessions (Table 5). EDA was significantly elevated in two-robot conditions compared to one-robot conditions across three metrics: tonic mean (β = 0.048, z = 2.43, p = 0.015), tonic standard deviation (β = 0.032, z = 2.36, p = 0.018), and normalized sympathetic index (β = 0.004, z = 2.51, p = 0.012). Skin temperature was also lower in two-robot conditions for both maximum (β = −0.005, z = −2.99, p = 0.003) and mean temperature (β = −0.005, z = −2.76, p = 0.006), consistent with peripheral vasoconstriction associated with sympathetic activation [39]. IBI-derived metrics corroborated the EDA and temperature findings, though these results should be interpreted with caution due to differential signal dropout across conditions. Mean IBI was significantly shorter in two-robot conditions (β = −0.036, z = −3.73, p < 0.001), indicating a faster heart rate, again consistent with increased sympathetic activation [37].
Subjective measures were consistent with the physiological pattern. Two-robot conditions produced measurably higher total workload (p = 0.001), effort (p < 0.001), temporal demand (p < 0.001), stress (p = 0.007), and attention (p = 0.017) compared to one-robot conditions. Two-robot conditions were also rated as more exciting (p = 0.040), suggesting the increased demand was accompanied by greater engagement. Perceived performance (p = 0.016) and robot predictability (p = 0.041) were also rated lower for two robots. Frustration did not differ significantly between one- and two-robot conditions after correction (uncorrected p = 0.047, corrected p = 0.959).
3.4. Robot Speed
Speed effects were present in both physiological (Table 6). and subjective measures (Table 7). Mixed speed was associated with a higher EDA tonic mean (β = 0.058, z = 2.25, p = 0.025) and tonic standard deviation (β = 0.041, z = 2.27, p = 0.023) relative to slow, and with shorter mean IBI (β = −0.049, z = −4.01, p < 0.001). Fast conditions were found to reduce HRV (β = −0.037, z = −2.02, p = 0.043), consistent with a dominant sympathetic response.
Table 6.
Single-factor Wilcoxon signed-rank results for speed. Cells show mean (SD). p-values are Holm–Bonferroni corrected. S = slow, M = mixed, F = fast. Bold indicates p < 0.05.
Table 7.
Physiological results for speed conditions. Cells show mean (SD). β indicates the model coefficient. Bold indicates p < 0.05.
Subjective stress was significantly elevated for both the fast (p = 0.003) and mixed (p = 0.001) speed conditions compared with the slow condition, with no significant difference between fast and mixed (p > 0.05). Total workload, effort, temporal demand, and mental demand were all higher for both the fast and mixed speed conditions relative to the slow condition (all p < 0.001). Excitement was elevated for both fast (p = 0.002) and mixed (p = 0.008) relative to slow, while attention was significantly elevated for fast (p = 0.03) with trends for mixed (p = 0.08). Robot predictability showed a trend toward lower ratings for mixed speed compared to slow (p = 0.055), whereas fast was not significant.
3.5. Interaction Model Results
A significant interaction was observed between speed and robot number for HR SD (β = −0.081, z = −2.16, p = 0.031). Reduced variability in heart rate occurred specifically in the fast speed, two-robot condition. No significant main effects were observed for speed or robots independently for this metric, indicating that the effect of speed depends on the number of robots monitored. This pattern suggests that reductions in heart rate variability emerge primarily when high robot speed coincides with monitoring multiple robots.
The fast two-robot condition was rated as the most demanding across all subjective measures, differing significantly from the slow one-robot condition for total workload (p = 0.001), effort (p = 0.001), temporal demand (p = 0.002), mental demand (p = 0.002), attention (p = 0.002), and stress (p = 0.014). This pattern offers partial support for H4: the slow two-robot condition did not produce higher subjective workload than the fast one-robot alternative, consistent with both representing comparably viable, lower-strain configurations relative to the fast two-robot condition. However, H4 specifically predicted an optimal tradeoff between productivity and emotional impact, and no objective productivity or throughput measure was collected in this study; the present data can therefore speak only to the emotional/workload half of H4, not to productivity, and H4 should accordingly be treated as partially rather than fully supported. Excitement was elevated for fast relative to slow within one-robot conditions (p = 0.019), but this difference did not persist within two-robot conditions (p = 1.00), suggesting a possible ceiling effect on engagement under higher workload. Robots × orientation and speed × orientation comparisons did not reveal interaction patterns beyond those attributable to robot number alone, consistent with the single-factor findings.
3.6. Hypothesis Summary
H1 (high speed → higher stress, workload, attention, excitement): Supported.
Fast and mixed speed produced significantly higher total workload, effort, temporal demand, mental demand, and stress than slow (Table 6), higher excitement (p = 0.002–0.008), and higher attention for fast specifically (p = 0.034), alongside corroborating EDA and IBI shifts (Table 7, Table 8 and Table 9).
Table 8.
Linear mixed-effects model results for robot number (one vs. two robots). β denotes the model coefficient, SE the standard error, z the Wald test statistic, and p the associated p-value.
Table 9.
Linear mixed-effects model results for speed. β denotes the model coefficient, SE the standard error, z the Wald test statistic, and p the associated p-value.
H2 (two robots → higher stress, workload, attention, excitement): Supported.
H3 (left-side focus → higher stress, workload, attention, excitement): Not supported.
Orientation produced no significant effects on any subjective or physiological measure; as discussed in our response to Comment 7, this null result is interpreted cautiously given the predominantly right-handed sample and fixed posture.
H4 (two robots + slow speed = best productivity/emotional tradeoff): Partially supported.
Slow two-robot and fast one-robot conditions did not differ significantly on subjective workload (Section 3.5), consistent with both being lower-strain alternatives to fast two-robot; however, no objective productivity data were collected, so the productivity component of H4 remains untested.
4. Discussion
The results suggest that robot number had a stronger impact on physiological stress than robot speed. Operating two robots consistently increased sympathetic activation, as indicated by elevated EDA and shorter IBIs, whereas speed showed weaker and less consistent physiological effects. At the subjective level, faster robot speeds increased attention and excitement without reducing perceived performance. In the two-factor analysis, the fast one-robot and slow two-robot conditions did not differ significantly on the subjective workload measures, suggesting that increases in robot speed and number may produce comparable perceived demand when considered individually. Taken together, these findings suggest a configuration involving a single robot operating at higher speed may represent a favorable balance between productivity, operator engagement, and physiological workload, but that configurations involving more robots at a slower speed may be suitable as a secondary alternative.
Across both subjective and physiological measures, the two-robot condition consistently reflected greater demand, confirming H2. Participants reported higher workload, effort, and stress when managing two robots, which was supported by the physiological signals. EDA increased in the two-robot condition across tonic mean, tonic variability, and normalized sympathetic index, while mean IBI decreased, indicating elevated heart rate. Because EDA is controlled by sympathetic activity, increases in tonic conductance levels are widely interpreted as reflecting heightened sympathetic arousal associated with stress and cognitive effort [35]. Together, these physiological changes suggest greater autonomic activation when participants coordinated two robots. Correlational analyses further supported this interpretation: perceived workload measures were strongly interrelated and negatively associated with perceived performance, while robot predictability showed moderate negative correlations with stress and workload.
The increased workload observed in the two-robot condition is consistent with established models of human supervision of autonomous systems. When operators manage multiple autonomous agents simultaneously, attentional resources must be divided across multiple information sources and task demands. Supervisory control research has shown that such environments can create queues for operator attention and increase cognitive load as multiple systems compete for monitoring and intervention [40]. More broadly, models of human–automation interaction suggest that automation does not simply reduce human workload but changes the nature of human activity, shifting the operator’s role toward monitoring the state of the system, interpreting information, and deciding when intervention is required [41]. As the number of robots increases, these monitoring and coordination demands may therefore increase even when the robots operate autonomously. The elevated subjective workload and physiological arousal observed in the two-robot condition are consistent with this interpretation, suggesting that managing multiple robots imposes additional attentional and situational awareness demands on the operator.
Higher robot speeds consistently increased perceived cognitive load, stress, attention, and excitement, as reflected in both subjective and physiological measures. In particular, faster robot motion was associated with increased EDA and shorter mean IBI, indicating elevated autonomic arousal and supporting H1. One likely explanation is that higher speeds reduce robot legibility and the time available for human prediction and response. As a result, operators must maintain more continuous situational awareness in order to anticipate robot trajectories and avoid potential conflicts. Similar patterns have been reported in previous studies of human–robot collaboration: increased robot speed has been linked to higher perceived risk, greater monitoring demands, and elevated mental workload [8,10,42]. Together, these findings suggest that faster robot motion increases operator demand by increasing both the cognitive effort required to track robot behavior and the perceived urgency of decision making.
Spatial orientation did not have a significant effect on subjective or physiological measurements, rejecting H3. This diverges from the findings of Rückert et al. [17], who found that use of the dominant hand improved collaborative assembly. A likely explanation lies in features of the present experimental design rather than in orientation being generally unimportant. Twenty-nine of the thirty participants were right-handed, and none were required to switch hands based on robot side, so left- and right-focused sessions likely both engaged the dominant hand regardless of condition. In addition, the seating and workstation layout were fixed and did not require participants to physically reorient their posture toward the active robot. Together, these design features may have suppressed a true orientation effect rather than demonstrating that robot left–right orientation has no bearing on operator experience. Under this interpretation, use of the dominant hand—rather than robot-side focus per se—may be the more relevant factor for collaborative performance, consistent with Rückert et al. [17]; however, the present design cannot fully disentangle these possibilities, and we treat the null orientation result as inconclusive rather than as evidence that orientation is unimportant in human–robot collaboration more broadly.
The current findings are derived from a simplified laboratory environment. In industrial settings, operator stress may be influenced by additional factors such as the risk of physical injury, strict production quotas, or economic incentives. In real-world scenarios, a slow-moving robot could paradoxically increase stress by slowing workflow and reducing operator efficiency, despite reducing cognitive load or uncertainty. Thus, the relationship between robot configuration, speed, and operator stress may differ under realistic work pressures. With this in mind, a two-robot slow setting or one-robot fast setting, both of which were shown to produce less stress than the two-robot fast setting, could represent a favorable tradeoff between operator well-being and task demand—though we emphasize that this claim rests on workload and stress measures rather than measured productivity, and should be treated as a candidate configuration for validation rather than a settled recommendation. Future work should investigate how these laboratory-observed effects scale under industrial conditions, incorporating factors such as workload intensity, robot size, and task risk.
Several limitations should be acknowledged when interpreting these findings. First, the study relied on a relatively small, predominantly right-handed sample, which constrains generalizability and limits conclusions regarding orientation effects. Second, the brief exposure times may not capture long-term adaptation or cumulative stress responses during extended human–robot collaboration: each condition lasted only 270 s, and the full protocol 40–60 min, which cannot capture the cumulative fatigue, habituation, or chronic stress effects that would develop over an 8 h industrial shift or across repeated days of exposure. Our stress and workload measures should therefore be interpreted as acute, session-level responses to novel robot configurations rather than as predictors of sustained occupational strain; the applicability boundary of the present findings is accordingly limited to short-duration, novel exposures, and longitudinal or repeated-exposure designs are needed before extrapolating to industrial deployment. Third, the task environment was simplified relative to real-world industrial settings, where task complexity, physical risk, and productivity demands may substantially alter stress, mental workload, and attention. Finally, the use of small, lightweight robots may not generalize to collaborations with larger, more dangerous industrial manipulators.
A related consideration is that robot number and objective task demand were not fully independent in the present design. Because each robot delivered blocks continuously throughout the fixed 270 s session, the two-robot conditions necessarily produced a higher aggregate rate of block delivery than the one-robot conditions, independent of any additional monitoring burden imposed by a second robot. As a result, the elevated workload and stress observed in the two-robot condition cannot be attributed with certainty to the cognitive demands of supervising an additional agent alone; they may instead, or in addition, reflect the higher volume of incoming task material that participants were required to process and act on. Per-session block counts were not logged as a separate variable in the present dataset, so the relative contributions of monitoring demand and delivery-rate demand cannot be statistically disentangled here. We therefore treat the robot-number effect as reflecting a combination of supervisory and task-throughput demand rather than a pure measure of monitoring load, and we identify decoupling these two factors—for example, by holding block-delivery rate constant while varying robot number—as a priority for future work.
It is worth noting that elevated attention and excitement in the fast and two-robot conditions should not automatically be interpreted as undesirable. These measures index engagement and arousal, whereas stress and workload capture perceived strain. Their co-occurrence here does not mean the conditions were purely aversive—increased excitement may instead reflect heightened engagement, consistent with attention and excitement being only weakly correlated with the workload cluster (ρ ≤ 0.38) while moderately correlated with each other (ρ = 0.51). We treat stress and workload as our primary strain indicators, and interpret attention and excitement as reflecting engagement, which can be a positive feature of a configuration provided it is not paired with disproportionate stress.
Additionally, the sample was drawn from a young college community (ages 18–48, mean age 24, primarily students), which limits generalizability to other populations who may encounter collaborative robots in real-world settings. Older adults in particular may perceive robot speed, number, and orientation differently than younger operators, with distinct considerations around safety, usability, and acceptance of robotic assistance [43]. As cobot deployment expands into assistive and long-term care contexts, where older adults are a primary user population, future work should extend the present paradigm to more age-diverse samples to determine whether the stress and workload patterns observed here hold across the lifespan.
Despite these limitations, this study provides initial evidence that robot number, speed, and orientation interact to shape operator cognitive and emotional states. Slow speeds and lower robot number attenuate stress and workload. Future work should pair these workload measures with objective throughput metrics (e.g., blocks stacked per session, error rate) to formally evaluate the tradeoff. Future studies should further investigate these relationships in ecologically valid environments, with balanced samples, objective performance metrics, and manipulations of task demand and risk to fully understand the human factors implications of multi-robot collaboration.
5. Conclusions
This study investigated the effect of robot configuration on operators during human–robot collaboration, and found that increasing robot number and speed elevated stress, mental workload, attention, and excitement while reducing perceived predictability. Slow robot speeds mitigated these effects, lowering negative workload components and enhancing predictability. Orientation produced no significant results in this study; given the predominantly right-handed sample and fixed workstation layout, this null result is best interpreted as inconclusive regarding the role of robot orientation, rather than as evidence that it is unimportant to human–robot collaboration more broadly.
These findings have clear design implications for collaborative workstations: robot speed and reduced robot number should be moderated to minimize stress, two robots at slow speed or one robot at fast speed produced lower stress and mental workload than setups with two robots at fast speed, and robot orientation can be left- or right-hand sided. H4, which predicted that two robots at slow speed would represent the optimal tradeoff between productivity and emotional impact, is only partially supported: the workload evidence favors this configuration as one viable low-strain option among others, but the productivity component of H4 was not tested here, as no objective performance or throughput metric was collected. Confirming H4 will require future work that pairs these workload and physiological measures with objective productivity data. Future work should extend these results to longer exposure periods, explore alternative robot orientations (e.g., angled or frontal placements), and test more diverse participant populations. Additional studies should also evaluate the effects of task complexity and sample variability. Such research will provide deeper insight into configurations that favorably balance productivity, engagement, and operator well-being in human–robot collaboration.
Supplementary Materials
The following supporting information can be downloaded at: https://www.mdpi.com/article/10.3390/mti10090097/s1, Table S1. Spearman correlation coefficients (ρ) among subjective measures.
Author Contributions
Q.Z.: Conceptualization, Methodology, Supervision, Writing—review and editing. N.M.S.: Data curation, Formal analysis, Writing—original draft. J.J.: Formal analysis, Writing—review and editing. J.S.: Data curation, Software. M.Y.W.: Supervision, Writing—review and editing. All authors have read and agreed to the published version of the manuscript.
Funding
This study was approved by the College of Charleston Institutional Review Board and was conducted in compliance with the American Psychological Association Code of Ethics. All participants provided written informed consent prior to participation. This study received no external funding or financial support.
Institutional Review Board Statement
The study was approved by the College of Charleston (Approval Code: #2023-03-001, dated 27 March 2023) for studies involving humans.
Informed Consent Statement
Written informed consent was obtained from all participants prior to their involvement in the study.
Data Availability Statement
The original contributions presented in this study are included in the article/Supplementary Materials. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Braěança, S.; Costa, E.; Castellucci, I.; Arezes, P. A brief overview of the use of collaborative robots in industry 4.0: Human role and safety. In Advances in Intelligent Systems and Computing; Springer: Berlin/Heidelberg, Germany, 2019; Volume 903, pp. 641–650. [Google Scholar] [CrossRef] [Scilit]
- Frank, A.G.; Dalenogare, L.S.; Ayala, N.F. Industry 4.0 technologies: Implementation patterns in manufacturing companies. Int. J. Prod. Econ. 2019, 210, 15–26. [Google Scholar] [CrossRef] [Scilit]
- Kim, W.; Lorenzini, M.; Balatti, P.; Nguyen, P.D.; Pattacini, U.; Tikhanoff, V.; Petrnel, L.; Fantacci, C.; Natale, L.; Metta, G.; et al. Adaptable workstations for human-robot collaboration: A reconfigurable framework for improving worker ergonomics and productivity. IEEE Robot. Autom. Mag. 2019, 26, 14–26. [Google Scholar] [CrossRef] [Scilit]
- Wang, W.; Chen, Y.; Diekel, Z.M.; Jia, Y. Cost functions based dynamic optimization for robot action planning. In Companion of the 2018 ACM/IEEE International Conference on Human-Robot Interaction; Association for Computing Machinery: New York, NY, USA, 2018; pp. 277–278. [Google Scholar] [CrossRef] [Scilit]
- Martin, P.; Daille-Lefevre, B.; Marsot, J.; Godot, X.; Abba, G.; Siadat, A.; Gomez-Echeverri, J.-C. New issues for workers safety in the factory of the future. In Advances in Intelligent Systems and Computing; Springer: Berlin/Heidelberg, Germany, 2019; pp. 307–315. [Google Scholar] [CrossRef] [Scilit]
- Beetz, M.; Bartels, G.; Albu-Schäffer, A.; Bálint-Benczédi, F.; Belder, R.; Beßler, D.; Haddadin, S.; Maldonado, A.; Mansfeld, N.; Wiedemeyer, T.; et al. Robotic agents capable of natural and safe physical interaction with human co-workers. In 2015 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS); IEEE: New York, NY, USA, 2015; pp. 6528–6535. [Google Scholar] [CrossRef] [Scilit]
- Briken, K.; Moore, J.; Scholarios, D.; Rose, E.; Sherlock, A. Industry 5 and the human in human-centric manufacturing. Sensors 2023, 23, 6416. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Arai, T.; Kato, R.; Fujita, M. Assessment of operator stress induced by robot collaboration in assembly. CIRP Ann. 2010, 59, 5–8. [Google Scholar] [CrossRef] [Scilit]
- Carissoli, C.; Negri, L.; Bassi, M.; Storm, F.A.; Fave, A.D. Mental workload and human-robot interaction in collaborative tasks: A scoping review. Int. J. Hum.–Comput. Interact. 2024, 40, 6458–6477. [Google Scholar] [CrossRef] [Scilit]
- Fujita, M.; Kato, R.; Tamio, A. Assessment of operators’ mental strain induced by hand-over motion of industrial robot manipulator. In 19th International Symposium in Robot and Human Interactive Communication; IEEE: New York, NY, USA, 2010; pp. 361–366. [Google Scholar] [CrossRef] [Scilit]
- Gervasi, R.; Aliev, K.; Mastrogiacomo, L.; Franceschini, F. User experience and physiological response in human-robot collaboration: A preliminary investigation. J. Intell. Robot. Syst. 2022, 106, 36. [Google Scholar] [CrossRef] [Scilit]
- Kato, R.; Fujita, M.; Arai, T. Development of advanced cellular manufacturing system with human-robot collaboration. In 19th International Symposium in Robot and Human Interactive Communication; IEEE: New York, NY, USA, 2010; pp. 355–360. [Google Scholar] [CrossRef] [Scilit]
- Koppenborg, M.; Nickel, P.; Naber, B.; Lungfiel, A.; Huelke, M. Effects of movement speed and predictability in human–robot collaboration. Hum. Factors Ergon. Manuf. Serv. Ind. 2017, 27, 197–209. [Google Scholar] [CrossRef] [Scilit]
- Lu, L.; Xie, Z.; Wang, H.; Li, L.; Xu, X. Mental stress and safety awareness during human-robot collaboration—Review. Appl. Ergon. 2022, 105, 103832. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kaduk, J.; Cavdan, M.; Drewing, K.; Hamann, H. From one to many: How active robot swarm sizes influence human cognitive processes. In 2024 33rd IEEE International Conference on Robot and Human Interactive Communication (RO-MAN); IEEE: New York, NY, USA, 2024; pp. 1207–1212. [Google Scholar] [CrossRef] [Scilit]
- Hostettler, D.; Mayer, S.; Albert, J.L.; Jenss, K.E.; Hildebrand, C. Real-time adaptive industrial robots: Improving safety and comfort in human-robot collaboration. In Proceedings of the 2025 CHI Conference on Human Factors in Computing Systems; Association for Computing Machinery: New York, NY, USA, 2025. [Google Scholar] [CrossRef] [Scilit]
- Rückert, P.; Tamke, M.; Eisfeld, T.; Gäer, M.; Grzeschik, J.; Preuß, T.; Plümer, S.; Tracht, K. Consideration of handedness in human-robot collaboration. Procedia CIRP 2024, 126, 158–163. [Google Scholar] [CrossRef] [Scilit]
- Yan, X.; Jia, Y. A review on human comfort factors, measurements, and improvements in human-robot collaboration. Sensors 2022, 22, 7431. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Hopko, S.; Wang, J.; Mehta, R. Human factors considerations and metrics in shared space human-robot collaboration: A systematic review. Front. Robot. AI 2022, 9, 799522. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Mariscal, M.A.; Barcina, S.O.; Herrero, S.G.; Perea, E.M.L. Working with collaborative robots and its influence on levels of working stress. Int. J. Comput. Integr. Manuf. 2023, 37, 900–919. [Google Scholar] [CrossRef] [Scilit]
- Müller, S.L.; Stiehm, S.; Jeschke, S.; Richert, A. Subjective stress in hybrid collaboration. In Social Robotics; Kheddar, A., Yoshida, E., Ge, S.S., Suzuki, K., Cabibihan, J.-J., Eyssel, F., He, H., Eds.; Springer International Publishing: Cham, Switzerland, 2017; pp. 597–606. [Google Scholar] [CrossRef] [Scilit]
- Bussolan, A.; Baraldo, S.; Gambardella, L.M.; Valente, A. Assessing the impact of human-robot collaboration on stress levels and cognitive load in industrial assembly tasks. In ISR Europe 2023; 56th International Symposium on Robotics; VDE: Berlin, Germany, 2023; pp. 78–85. [Google Scholar]
- Gervasi, C.; Mastrogiacomo, F. Analyzing psychophysical state and cognitive performance in human-robot collaboration for repetitive assembly processes. Prod. Eng. 2024, 18, 19–33. [Google Scholar] [CrossRef] [Scilit]
- Rinaldi, M.; Natale, C.; Fera, M.; Macchiaroli, R.; Monaco, M.G.L.; Grosse, E.H. Evaluation of mental stress in human-robot interaction: An explorative study. Procedia Comput. Sci. 2024, 232, 726–735. [Google Scholar] [CrossRef] [Scilit]
- Lazarus, R.S.; Folkman, S. Stress, Appraisal, and Coping, 1st ed.; Springer Publishing Company: New York, NY, USA, 1984. [Google Scholar]
- Longo, L.; Wickens, C.D.; Hancock, G.; Hancock, P.A. Corrigendum: Human mental workload: A survey and a novel inclusive definition. Front. Psychol. 2022, 13, 883321. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Posner, M.I.; Peterson, S.E. The attention system of the human brain. Annu. Rev. Neurosci. 1990, 13, 25–42. [Google Scholar] [CrossRef] [PubMed]
- Hoff, K.A.; Bashir, M. Trust in automation: Integrating empirical evidence on factors that influence trust. Hum. Factors 2015, 57, 407–434. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Russell, J.A. A circumplex model of affect. J. Personal. Soc. Psychol. 1980, 39, 1161–1178. [Google Scholar] [CrossRef] [Scilit]
- Hart, S.G.; Staveland, L.E. Development of NASA-TLX (Task Load Index): Results of empirical and theoretical research. In Human Mental Workload. North-Holland, Amsterdam; Hancock, P.A., Meshkati, N., Eds.; North Holland Press: Amsterdam, The Netherlands, 1988; pp. 139–183. [Google Scholar] [CrossRef] [Scilit]
- Herborn, K.A.; Graves, J.L.; Jerem, P.; Evans, N.P.; Nager, R.; McCafferty, D.J.; McKeegan, D.E. Skin temperature reveals the intensity of acute stress. Physiol. Behav. 2015, 152, 225–230. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Kim, H.G.; Cheon, E.J.; Bai, D.S.; Lee, Y.H.; Koo, B.-H. Stress and heart rate variability: A meta-analysis and review of the literature. Psychiatry Investig. 2018, 15, 235–245. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Shaffer, F.; Ginsberg, J.P. An overview of heart rate variability metrics and norms. Front. Public Health 2017, 5, 258. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Makowski, D.; Pham, T.; Lau, Z.J.; Brammer, J.C.; Lespinasse, F.; Pham, H.; Schölzel, C.; Chen, S.H.A. NeuroKit2: A Python toolbox for neurophysiological signal processing. Behav. Res. Methods 2021, 53, 1689–1696. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Boucsein, W. Electrodermal Activity; Springer Science & Business Media: New York, NY, USA, 2012. [Google Scholar]
- Joshi, R.; Kommers, D.; Guo, C.; Bikker, J.-W.; Feijs, L.; van Pul, C.; Andriessen, P. Statistical modeling of heart rate variability to unravel the factors affecting autonomic regulation in preterm infants. Sci. Rep. 2019, 9, 7691. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Task Force of the European Society of Cardiology and the North American Society of Pacing and Electrophysiology. Heart rate variability: Standards of measurement, physiological interpretation, and clinical use. Circulation 1996, 93, 1043–1065. [Google Scholar] [PubMed]
- Likert, R. A technique for the measurement of attitudes. Arch. Psychol. 1932, 140, 1–55. [Google Scholar]
- Charkoudian, N. Skin blood flow in adult human thermoregulation: How it works, when it does not, and why. Mayo Clin. Proc. 2003, 78, 603–612. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Cummings, M.L.; Mitchell, P.J. Predicting controller capacity in supervisory control of multiple UAVs. In Proceedings of the IEEE International Conference on Systems, Man and Cybernetics; IEEE: New York, NY, USA, 2007; pp. 1189–1194. [Google Scholar] [CrossRef] [Scilit]
- Parasuraman, R.; Sheridan, T.B.; Wickens, C.D. A model for types and levels of human interaction with automation. IEEE Trans. Syst. Man. Cybern. A 2000, 30, 286–297. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Apraiz Iriarte, A.; Lasa, G.; Mazmela, M.; Arana-Arexolaleiba, N.; Serrano Muñoz, A.; Elguea-Aguinaco, Í.; Etxabe, A. Evaluating the effect of speed and acceleration on human factors during an assembly task in human-robot interaction (HRI). Int. J. Soc. Robot. 2025, 17, 211–256. [Google Scholar] [CrossRef] [Scilit]
- Fan, J.; Mion, L.C.; Beuscher, L.; Ullal, A.; Newhouse, P.A.; Sarkar, N. SAR-Connect: A socially assistive robotic system to support activity and social engagement of older adults. IEEE Trans. Robot. 2021, 38, 1250–1269. [Google Scholar] [CrossRef] [Scilit] [PubMed]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.