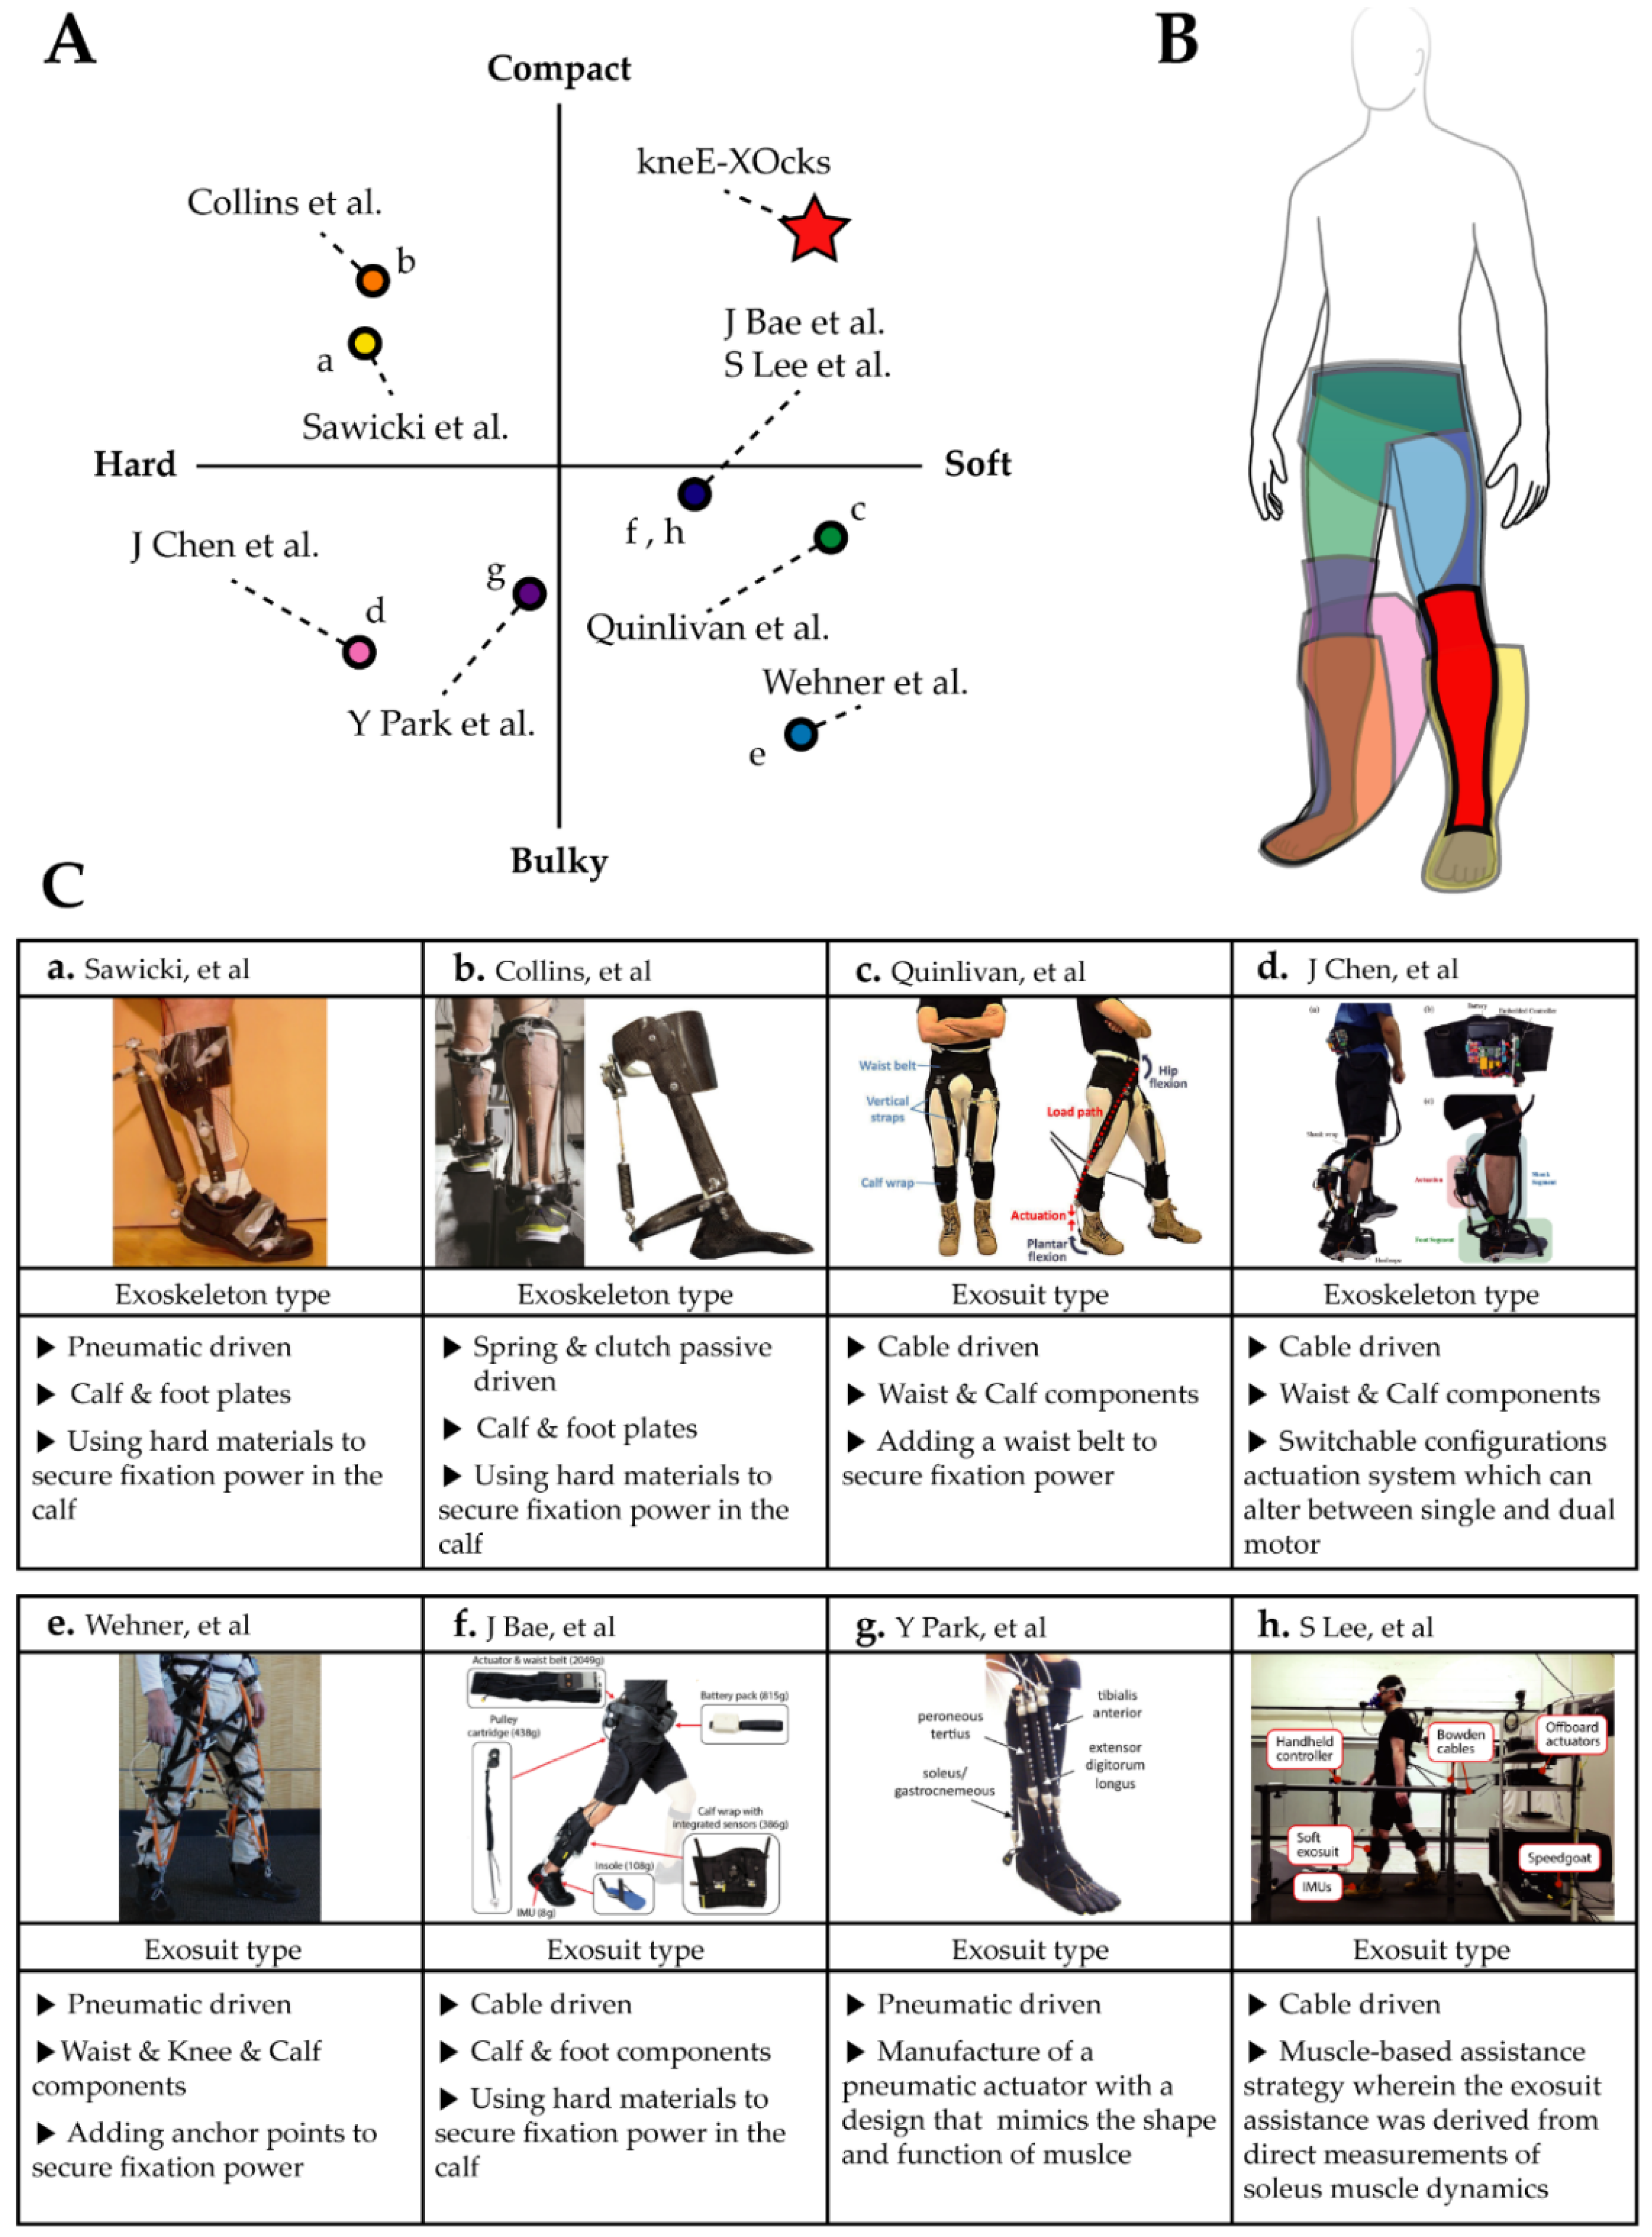
Lighter and Simpler Design Paradigm for Widespread Use of Ankle Exosuits Based on Bio-Inspired Patterns


Abstract
Share and Cite
Park, S.; Moon, J.; Park, J.i.; Ryu, J.; Nam, K.; Yang, J.; Lee, G. Lighter and Simpler Design Paradigm for Widespread Use of Ankle Exosuits Based on Bio-Inspired Patterns. Biomimetics 2022, 7, 148. https://doi.org/10.3390/biomimetics7040148
Park S, Moon J, Park Ji, Ryu J, Nam K, Yang J, Lee G. Lighter and Simpler Design Paradigm for Widespread Use of Ankle Exosuits Based on Bio-Inspired Patterns. Biomimetics. 2022; 7(4):148. https://doi.org/10.3390/biomimetics7040148
Chicago/Turabian StylePark, Sungjin, Junyoung Moon, June il Park, Jaewook Ryu, Kimoon Nam, Jaeha Yang, and Giuk Lee. 2022. "Lighter and Simpler Design Paradigm for Widespread Use of Ankle Exosuits Based on Bio-Inspired Patterns" Biomimetics 7, no. 4: 148. https://doi.org/10.3390/biomimetics7040148
APA StylePark, S., Moon, J., Park, J. i., Ryu, J., Nam, K., Yang, J., & Lee, G. (2022). Lighter and Simpler Design Paradigm for Widespread Use of Ankle Exosuits Based on Bio-Inspired Patterns. Biomimetics, 7(4), 148. https://doi.org/10.3390/biomimetics7040148