Next Issue
Volume 10, November
Previous Issue
Volume 10, September


Biomimetics, Volume 10, Issue 10 (October 2025) – 76 articles
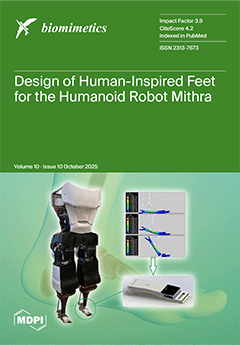
Cover Story (view full-size image): We present the foot design for the humanoid robot Mithra, with the goal of biomimetically improving impact behavior, natural power cycling throughout the gait cycle, and balance. For this purpose, an optimization framework was built which evaluates the human-inspired objectives using a dynamic finite element analysis validated by benchtop experiments. Using this framework and through several concept design iterations, a low-cost, compliant foot was optimized, designed, and fabricated. The analyses showed that the optimized foot significantly outperformed the baseline rigid foot in approaching the characteristics of human feet. The proposed framework is not limited to humanoids and can also be applied to foot design for lower-limb prostheses and exoskeletons. View this paper
  • Issues are regarded as officially published after their release is announced to the table of contents alert mailing list.
  • You may sign up for e-mail alerts to receive table of contents of newly released issues.
  • PDF is the official format for papers published in both, html and pdf forms. To view the papers in pdf format, click on the "PDF Full-text" link, and use the free Adobe Reader to open them.
Order results
Result details
Section
Select all
Export citation of selected articles as:
11 pages, 1595 KB  
Article
Enhancing Gait Symmetry via Intact Limb Kinematic Mapping Control of a Hip Disarticulation Prosthesis
by Shengli Luo, Xiaolong Shu, Jiahao Du, Hui Li and Hongliu Yu
Biomimetics 2025, 10(10), 714; https://doi.org/10.3390/biomimetics10100714 - 21 Oct 2025
Cited by 1 | Viewed by 1581
Abstract
Conventional hip disarticulation prostheses often require amputees to produce limited leg-lifting torque through exaggerated pelvic motion, resulting in complex control and pronounced gait abnormalities. To overcome the limitations, we present a mapping control strategy for a powered hip disarticulation prosthesis aimed at improving [...] Read more.
Conventional hip disarticulation prostheses often require amputees to produce limited leg-lifting torque through exaggerated pelvic motion, resulting in complex control and pronounced gait abnormalities. To overcome the limitations, we present a mapping control strategy for a powered hip disarticulation prosthesis aimed at improving gait symmetry. A quaternion-based method was implemented to capture hip joint kinematics, while a gated recurrent unit (GRU) neural network was trained to model the kinematic relationship between the intact and prosthetic limbs, enabling biomimetic trajectory control. Validation experiments showed that trajectory similarity between predicted and actual motions increased with walking speed, reaching 98.12% at 3.0 km/h. Comparative walking tests revealed an 84.00% improvement in hip flexion angle with the powered prosthesis over conventional designs. Notable improvements in gait symmetry were observed: stride symmetry (measured by SI and RII) improved by 23.21% and 19.28%, respectively, while hip trajectory symmetry increased by 68.07% (SI) and 47.59% (RII). These results confirm that the GRU-based kinematic mapping model offers robust trajectory prediction and that the powered prosthesis significantly enhances gait symmetry, delivering more natural and biomimetic motion. Full article
(This article belongs to the Special Issue Bionic Engineering Materials and Structural Design)
Show Figures

Figure 1

29 pages, 4164 KB  
Review
Multimodal Field-Driven Actuation in Bioinspired Robots: An Emerging Taxonomy and Roadmap Towards Hybrid Intelligence
by Jianping Wang, Xin Wang, Shuai Zhou and Gengbiao Chen
Biomimetics 2025, 10(10), 713; https://doi.org/10.3390/biomimetics10100713 - 21 Oct 2025
Viewed by 1935
Abstract
Rigid–flexible coupled robots hold significant potential for operating in unstructured environments, but a systematic analysis of their actuation strategies across diverse physical fields is notably lacking in the literature. This review addresses this gap by introducing a novel taxonomy based on field-controlled evolutionary [...] Read more.
Rigid–flexible coupled robots hold significant potential for operating in unstructured environments, but a systematic analysis of their actuation strategies across diverse physical fields is notably lacking in the literature. This review addresses this gap by introducing a novel taxonomy based on field-controlled evolutionary pathways—mechanical → electromagnetic → chemical → biohybrid—and critically examining over 100 seminal studies through a six-dimensional framework encompassing design, dynamics, and performance. We demonstrate that hybrid field integration (e.g., pneumatic-chemical synergy) improves grasping robustness by 40% in cluttered environments compared to single-field systems. Notably, biohybrid actuators, which integrate living cells, exhibit over 90% motion similarity to biological models, while phase-transition materials allow for adaptive stiffness tuning (0.1–5 N·mm−1) in medical applications. Radar chart analysis further reveals fundamental trade-offs between energy efficiency, response speed, and scalability across the various fields. These insights provide a clear roadmap for the development of next-generation robots with embodied intelligence, emphasizing multi-field synergies and bio-inspired adaptability. Full article
(This article belongs to the Special Issue Bioinspired Locomotion Control: From Biomechanics to Robotics)
Show Figures

Figure 1

21 pages, 2078 KB  
Article
Semi-Automatic System for ZnO Nanoflakes Synthesis via Electrodeposition Using Bioinspired Neuro-Fuzzy Control
by Yazmín Mariela Hernández-Rodríguez, Yunia Veronica Garcia-Tejeda, Esperanza Baños-López and Oscar Eduardo Cigarroa-Mayorga
Biomimetics 2025, 10(10), 712; https://doi.org/10.3390/biomimetics10100712 - 21 Oct 2025
Cited by 3 | Viewed by 1079
Abstract
This research presents the development and characterization of a semi-automatic electrophoretic deposition (EPD) system designed for the synthesis of zinc oxide (ZnO) microstructures, utilizing a bioinspired neuro-fuzzy control strategy (ANFIS). The system was designed based on a chemical reactor regulated by electricity in [...] Read more.
This research presents the development and characterization of a semi-automatic electrophoretic deposition (EPD) system designed for the synthesis of zinc oxide (ZnO) microstructures, utilizing a bioinspired neuro-fuzzy control strategy (ANFIS). The system was designed based on a chemical reactor regulated by electricity in a potentiostate cell to automate and optimize the deposition parameters by controlling the temperature. The synthesized ZnO coatings exhibited distinctive flake-like morphology, confirmed via Scanning Electron Microscopy (SEM), X-Ray Diffraction (XRD), and Energy-Dispersive X-Ray Spectroscopy (EDS), validating their morphological uniformity and compositional consistency. The implemented ANFIS controller was trained using experimentally acquired data, making a correlation with the properties of the sample, thickness and porosity, also employed as inputs of the system. The system exhibited high accuracy in predicting optimal deposition conditions for ZnO nanoflakes obtention, specifically in the temperature-dependent variations in thickness and porosity employed as reference to establish four classes of working sets based on the density of ZnO flakes in the substrate. Results indicate that the bioinspired neuro-fuzzy control substantially enhances the adaptability and predictive capabilities of the electrophoretic deposition process, making it a versatile tool suitable for various applications requiring precise microstructural characteristics. Future directions include further refinement of the control system, incorporation of digital sensing technologies, and potential expansion of the platform to accommodate other functional materials and complex deposition scenarios. Full article
Show Figures

Graphical abstract

24 pages, 5277 KB  
Article
Biomimetic Shading Systems: Integrating Motorised and Moisture-Responsive Actuation for Adaptive Façades
by Negin Imani, Marie-Joo Le Guen, Nathaniel Bedggood, Caelum Betteridge, Christian Gauss and Maxime Barbier
Biomimetics 2025, 10(10), 711; https://doi.org/10.3390/biomimetics10100711 - 20 Oct 2025
Cited by 4 | Viewed by 3046
Abstract
A biomimetic adaptive façade applies natural principles to building design using shading devices that dynamically respond to environmental changes, enhancing daylight, thermal comfort, and energy efficiency. While motorised systems offer precision through sensors and mechanical actuation, they consume energy and are complex. In [...] Read more.
A biomimetic adaptive façade applies natural principles to building design using shading devices that dynamically respond to environmental changes, enhancing daylight, thermal comfort, and energy efficiency. While motorised systems offer precision through sensors and mechanical actuation, they consume energy and are complex. In contrast, passively actuated systems use smart materials that respond to environmental stimuli, offering simpler and more sustainable operation, but often lack responsiveness to dynamic conditions. This study explores a sequential approach by initially developing motorised shading concepts before transitioning to a passive actuation strategy. In the first phase, nine mechanically actuated shading device concepts were designed, inspired by the opening and closing behaviour of plant stomata, and evaluated on structural robustness, actuation efficiency, ease of installation, and visual integration. One concept was selected for further development. In the second phase, a biocomposite made of polylactic acid (PLA) and regenerated cellulose fibres was used for Fused Deposition Modelling (FDM) to fabricate 3D-printed modules with passive, moisture-responsive actuation. The modules underwent environmental testing, demonstrating repeatable shape changes in response to heat and moisture. Moisture application increased the range of motion, and heating led to flap closure as water evaporated. Reinforcement and layering strategies were also explored to optimise movement and minimise unwanted deformation, highlighting the material’s potential for sustainable, responsive façade systems. Full article
(This article belongs to the Special Issue Biomimetic Adaptive Buildings)
Show Figures

Figure 1

27 pages, 8102 KB  
Article
Extended Kalman Filter-Based Visual Odometry in Dynamic Environments Using Modified 1-Point RANSAC
by Jinhee Lee and Jaeyoung Kang
Biomimetics 2025, 10(10), 710; https://doi.org/10.3390/biomimetics10100710 - 20 Oct 2025
Cited by 1 | Viewed by 1970
Abstract
Visual odometry in dynamic environments is particularly challenging, as moving objects often cause incorrect data associations and large pose estimation errors. Traditional EKF-based VO methods rely on 1-point RANSAC to reject outliers under the assumption of a static world, thereby discarding dynamic landmarks [...] Read more.
Visual odometry in dynamic environments is particularly challenging, as moving objects often cause incorrect data associations and large pose estimation errors. Traditional EKF-based VO methods rely on 1-point RANSAC to reject outliers under the assumption of a static world, thereby discarding dynamic landmarks as noise. However, in practice, outliers may arise not only from measurement errors but also from the motion of objects. To address this issue, we propose a modified 1-point RANSAC framework that detects dynamic objects and leverages both static and dynamic landmarks for ego-motion estimation. Inspired by adaptive strategies observed in biological vision systems, our approach integrates EKF-based state estimation with dynamic object tracking to achieve simultaneous ego-motion and object-motion estimation, improving robustness in complex and dynamic scenes. Full article
(This article belongs to the Special Issue Recent Advances in Bioinspired Robot and Intelligent Systems)
Show Figures

Figure 1

33 pages, 3248 KB  
Article
Weibull Parameter Estimation Using Empirical and AI Methods: A Wind Energy Assessment in İzmir
by Bayram Köse
Biomimetics 2025, 10(10), 709; https://doi.org/10.3390/biomimetics10100709 - 20 Oct 2025
Cited by 4 | Viewed by 1773
Abstract
This study evaluates the estimation of Weibull distribution parameters (shape, k; scale, c) for wind speed modeling in wind energy potential assessments. Traditional empirical methods—Justus Moment Method (JEM), Power Density Method (PDM), Energy Pattern Factor Method (EPFM), Lysen Moment Method (LAM), [...] Read more.
This study evaluates the estimation of Weibull distribution parameters (shape, k; scale, c) for wind speed modeling in wind energy potential assessments. Traditional empirical methods—Justus Moment Method (JEM), Power Density Method (PDM), Energy Pattern Factor Method (EPFM), Lysen Moment Method (LAM), and Standard Deviation Empirical Method (SEM)—are compared with advanced artificial intelligence optimization algorithms (AIOAs), including Genetic Algorithm (GA), Gravitational Search Algorithm (GSA), Sine Cosine Algorithm (SCA), Teaching-Learning-Based Optimization (TLBA), Grey Wolf Optimizer (GWA), Red Fox Algorithm (RFA), and Red Panda Optimization Algorithm (RPA). Using hourly wind speed data from Foça, Urla, Karaburun, and Çeşme in Turkey, the analysis demonstrates that AIOAs, particularly GA, GSA, SCA, TLBA, and GWA, outperform empirical methods, achieving low RMSE (0.0071) and high R2 (0.9755). SEM and LAM perform competitively among empirical methods, while PDM and EPFM show higher errors, highlighting their limitations in complex wind speed distributions. The study also conducts a techno-economic analysis, assessing capacity factors, unit energy costs, and payback periods. Foça and Urla are identified as optimal investment sites due to high energy yields and economic efficiency, whereas Çeşme is unviable due to low production and long payback periods. This research provides a robust framework for Weibull parameter estimation, demonstrating AIOAs’ superior accuracy and offering a decision-support tool for sustainable wind energy investments. Full article
(This article belongs to the Special Issue Bio-Inspired Machine Learning and Evolutionary Computing)
Show Figures

Figure 1

32 pages, 1242 KB  
Article
Exemplar Learning and Memory Retrieval-Based Particle Swarm Optimization Algorithm with Engineering Applications
by Shuying Zhang, Xiaohong Hu, Yue Gao, Minghan Gao and Yufei Zhang
Biomimetics 2025, 10(10), 708; https://doi.org/10.3390/biomimetics10100708 - 19 Oct 2025
Cited by 5 | Viewed by 1118
Abstract
Particle swarm optimization (PSO) is a bio-inspired stochastic optimization algorithm that simulates the foraging behavior of birds. Despite its simplicity and efficiency, PSO often suffers from premature convergence and a poor balance between exploration and exploitation. These drawbacks mainly arise from its limited [...] Read more.
Particle swarm optimization (PSO) is a bio-inspired stochastic optimization algorithm that simulates the foraging behavior of birds. Despite its simplicity and efficiency, PSO often suffers from premature convergence and a poor balance between exploration and exploitation. These drawbacks mainly arise from its limited learning sources and rigid position update scheme. To address these issues, this paper proposes an enhanced PSO framework, termed Exemplar Learning and Memory Retrieval-Based Particle Swarm Optimization (EMPSO). The design of EMPSO is inspired by the learning, memory, and adaptation mechanisms observed in biological collectives. It integrates three complementary strategies to improve swarm intelligence. First, an elite exemplar learning mechanism aggregates the positional information of top-performing particles to construct a more reliable guidance vector. Second, a memory recall strategy retains exemplars that have recently contributed to global improvements and reuses them probabilistically with a recency bias, thus enabling effective knowledge inheritance. Third, an adaptive position update scheme assigns exploration- or exploitation-oriented behaviors to particles based on fitness ranking, promoting dynamic role differentiation within the swarm. Comprehensive experiments on the CEC2017 and CEC2022 benchmark suites demonstrate that EMPSO consistently outperforms six representative algorithms. Furthermore, applications to three engineering design problems and the optimal PMU placement task verify its robustness and practical effectiveness. Full article
(This article belongs to the Section Biological Optimisation and Management)
Show Figures

Graphical abstract

32 pages, 12133 KB  
Article
Modified Black-Winged Kite Optimization Algorithm with Three-Phase Attacking Strategy and Lévy–Cauchy Migration Behavior to Solve Mathematical Problems
by Yunpeng Ma, Wanting Meng, Ruixue Gu and Xinxin Zhang
Biomimetics 2025, 10(10), 707; https://doi.org/10.3390/biomimetics10100707 - 17 Oct 2025
Cited by 2 | Viewed by 1461
Abstract
The Black-winged Kite Algorithm (BKA) is a novel heuristic optimization algorithm proposed in 2024, which has demonstrated superior optimization performance on most CEC benchmark functions and several engineering problems. To further enhance its convergence accuracy and solution quality, this paper proposes a Modified [...] Read more.
The Black-winged Kite Algorithm (BKA) is a novel heuristic optimization algorithm proposed in 2024, which has demonstrated superior optimization performance on most CEC benchmark functions and several engineering problems. To further enhance its convergence accuracy and solution quality, this paper proposes a Modified Black-winged Kite Algorithm (MBKA). First, a three-phase attacking strategy is designed to replace the original BKA’s attacking mechanism, thereby enhancing population diversity and improving solution quality. Additionally, a Lévy–Cauchy migration strategy is incorporated to achieve a more effective balance between exploration and exploitation. The effectiveness of MBKA is assessed through extensive experiments on 18 classical benchmark functions, the CEC-2017 and CEC-2022 test suites, and two real-world engineering optimization problems. The results indicate that MBKA consistently outperforms the original BKA and several state-of-the-art algorithms in both convergence accuracy and convergence speed across most test cases. Full article
(This article belongs to the Section Biological Optimisation and Management)
Show Figures

Figure 1

29 pages, 1017 KB  
Article
Intelligent Automobile Bionic Cockpit Selection Considering Personalization Requirements: Multiple-Criterion Model and Decision-Making Method
by Liangliang Shi, Shaolin Zhang, Tao Han, Niansong Liu, Guoquan Xie and Guangdong Tian
Biomimetics 2025, 10(10), 706; https://doi.org/10.3390/biomimetics10100706 - 17 Oct 2025
Viewed by 1162
Abstract
The extensive integration of intelligent and bionic technologies in the automotive industry has significantly heightened interest in the advancement of smart vehicle cockpits. The growing demand for automobile cockpit functions makes the personalization of intelligent automobile bionic cockpits more challenging. In addition, the [...] Read more.
The extensive integration of intelligent and bionic technologies in the automotive industry has significantly heightened interest in the advancement of smart vehicle cockpits. The growing demand for automobile cockpit functions makes the personalization of intelligent automobile bionic cockpits more challenging. In addition, the evaluation and selection for cockpits considering multiple attributes remains incomplete, which hinders the development of intelligent automobile bionic cockpits. Thus, this paper constructed a multiple criterion model considering the personalization needs of drivers and passengers, which include comfort, security, and spiritual entertainment needs. A novel decision-making approach that merges the entropy measure and the Elimination and Choice Expressing Reality (ELECTRE) method is introduced to address the selection challenges of smart vehicle cockpits. This methodology incorporates the Spherical Fuzzy Set (SFS) to accurately gather and interpret the data within the decision matrix. This study employs a practical application by examining three types of intelligent automobile cockpits to validate the effectiveness of the proposed decision-making method. Through sensitivity analysis and comprehensive validation, the findings substantiate that the research offers a potent instrument for addressing the selection challenges associated with intelligent automobile cockpits, providing valuable insights for designers. Full article
(This article belongs to the Special Issue Computer-Aided Biomimetics: 3rd Edition)
Show Figures

Figure 1

18 pages, 5303 KB  
Article
Mechanical Analysis and Multi-Objective Optimization of Origami-Inspired Tree-Shaped Thin-Walled Structures Under Axial Impacts
by Honghao Zhang, Zilong Meng, Jixiang Zhang, Xinyu Hao, Shangbin Zhang and Niancheng Guo
Biomimetics 2025, 10(10), 705; https://doi.org/10.3390/biomimetics10100705 - 17 Oct 2025
Cited by 3 | Viewed by 1319
Abstract
Rail vehicles, frequently utilized as a heavy-duty, high-speed means of transportation, have been observed to result in substantial casualties and economic losses in the event of accidents. Energy-absorbing structures are critical to achieving passive safety, effectively absorbing and dissipating energy. The present study [...] Read more.
Rail vehicles, frequently utilized as a heavy-duty, high-speed means of transportation, have been observed to result in substantial casualties and economic losses in the event of accidents. Energy-absorbing structures are critical to achieving passive safety, effectively absorbing and dissipating energy. The present study utilizes numerical simulation to assess the performance of origami-inspired tree-shaped structures (OTSs) under diverse surface configurations. OTSs offer significant advantages in reducing IPCF without substantially compromising other performance metrics. This experimental approach is employed to validate the efficacy of a finite element model. A multi-criteria decision-making method integrates MOEA/D-DAE and TOPSIS. This integrated approach is employed to identify optimal structures. The validity of the method was established through a comparison of the predicted results with the outcomes of finite element analysis. The findings demonstrated a 31.2% reduction in IPCF, a 3.6% increase in SEA, and a 10.4% rise in ULC. The optimized IPCF is 4.9919 kN, SEA is 12.316 kJ/kg. The collective results indicate the efficacy of the method as a tool for analyzing and optimizing energy-absorbing structures. Full article
(This article belongs to the Special Issue Computer-Aided Biomimetics: 3rd Edition)
Show Figures

Figure 1

25 pages, 1835 KB  
Article
An Enhanced Moss Growth Optimization Algorithm with Outpost Mechanism and Early Stopping Strategy for Production Optimization in Tight Reservoirs
by Chenglong Wang, Chengqian Tan and Youyou Cheng
Biomimetics 2025, 10(10), 704; https://doi.org/10.3390/biomimetics10100704 - 17 Oct 2025
Cited by 1 | Viewed by 1061
Abstract
Optimization algorithms play a crucial role in solving complex problems in reservoir geology and engineering, particularly those involving highly non-linear, multi-parameter, and high-dimensional systems. In the context of reservoir development, accurate optimization is essential for enhancing hydrocarbon recovery, improving production efficiency, and managing [...] Read more.
Optimization algorithms play a crucial role in solving complex problems in reservoir geology and engineering, particularly those involving highly non-linear, multi-parameter, and high-dimensional systems. In the context of reservoir development, accurate optimization is essential for enhancing hydrocarbon recovery, improving production efficiency, and managing subsurface uncertainties. The Moss Growth Optimization (MGO) algorithm emulates the adaptive growth and reproductive strategies of moss. It provides a robust bio-inspired framework for global optimization. However, MGO often suffers from slow convergence and difficulty in escaping local optima in highly multimodal landscapes. To address these limitations, this paper proposes a novel algorithm called Strategic Moss Growth Optimization (SMGO). SMGO integrates two enhancements: an Outpost Mechanism (OM) and an Early Stopping Strategy (ESS). The OM improves exploitation by guiding individuals through multi-stage local search with Gaussian-distributed exploration around promising regions. This helps refine the search and prevents stagnation in sub-optimal areas. In parallel, the ESS periodically reinitializes the population using a run-and-reset procedure. This diversification allows the algorithm to escape local minima and maintain population diversity. Together, these strategies enable SMGO to accelerate convergence while ensuring solution quality. Its performance is rigorously evaluated on a suite of global optimization benchmarks and compared with state-of-the-art metaheuristics. The results show that SMGO achieves superior or highly competitive outcomes, with clear improvements in accuracy and stability. To demonstrate real-world applicability, SMGO is applied to production optimization in tight reservoirs. The algorithm identifies superior production strategies, leading to significant improvements in projected economic returns. This successful application highlights the robustness and practical value of SMGO. It offers a powerful and reliable optimization tool for complex engineering problems, particularly in strategic resource management for tight reservoir development. Full article
(This article belongs to the Special Issue Advances in Biological and Bio-Inspired Algorithms)
Show Figures

Figure 1

14 pages, 4294 KB  
Article
Biomimetic Silk Fibroin Scaffolds Functionalized with Hydroxyapatite and Platelet Growth Factors for Bone Tissue Engineering
by Mauro Pollini, Carmen Lanzillotti, Maria Antonietta De Sangro, Maria Rosaria Cazzato, Luciano Abbruzzese and Federica Paladini
Biomimetics 2025, 10(10), 703; https://doi.org/10.3390/biomimetics10100703 - 17 Oct 2025
Cited by 3 | Viewed by 1560
Abstract
Non-union fractures represent a significant clinical challenge requiring innovative therapeutic approaches. Silk fibroin (SF) scaffolds have gained recognition as advantageous biomaterials for bone tissue engineering due to their biocompatibility and mechanical characteristics. This study investigated the biocompatibility and osteoinductive potential of SF scaffolds [...] Read more.
Non-union fractures represent a significant clinical challenge requiring innovative therapeutic approaches. Silk fibroin (SF) scaffolds have gained recognition as advantageous biomaterials for bone tissue engineering due to their biocompatibility and mechanical characteristics. This study investigated the biocompatibility and osteoinductive potential of SF scaffolds functionalized with hydroxyapatite (HA) and loaded with platelet growth factors (PGFs) using hematopoietic stem cells (HSCs). SF scaffolds were prepared and functionalized with HA through methanol impregnation, while PGFs were obtained from platelet lysate via apheresis procedures. HSCs were cultured on different experimental groups, namely SF, SF-HA, PGF, SF-PGF, and SF-HA-PGF, assessing biocompatibility through 3-(4,5-dimethylthiazol-2-yl)-2,5-diphenyltetrazolium bromide (MTT) assay, Live/Dead staining, and cytoskeleton analysis over 7 days. Osteoinductive properties were evaluated using Alizarin Red staining for mineral matrix deposition at 14 and 21 days. The MTT assay revealed the biocompatibility of all the experimental groups. The Live/Dead assay confirmed high cell viability, while the cytoskeleton analysis revealed well-organized actin filaments comparable to controls. Alizarin Red staining showed that PGF alone promoted early mineral matrix deposition at day 14, while SF-HA, SF-PGF, and SF-HA-PGF groups demonstrated significantly enhanced mineralization at day 21 compared with SF alone. The combination of silk fibroin scaffolds with platelet growth factors alone or with hydroxyapatite and platelet growth factors creates a biomimetic environment that supports cell viability and induces the osteogenic differentiation of hemopoietic stem cells. These findings suggest significant potential for clinical translation in treating non-union fractures and bone defects. Full article
(This article belongs to the Special Issue Biomimicry and Functional Materials: 5th Edition)
Show Figures

Figure 1

19 pages, 4236 KB  
Article
Crashworthiness Performance of Bamboo-Inspired 3D-Printed Tubes: Effects of Infill Pattern, Infill Ratio, Wall Thickness, and Inner Diameter
by Emre İsa Albak
Biomimetics 2025, 10(10), 702; https://doi.org/10.3390/biomimetics10100702 - 17 Oct 2025
Cited by 13 | Viewed by 1786
Abstract
This study investigates the impact absorption performance of bamboo-inspired 3D-printed circular tubes in terms of infill type (grid, gyroid, honeycomb, Archimedean chords), infill ratio (10%, 20%, 30%, and 40%), wall thickness (0.8, 1.2, 1.6, and 2.0 mm), and inner diameter parameters. The structures [...] Read more.
This study investigates the impact absorption performance of bamboo-inspired 3D-printed circular tubes in terms of infill type (grid, gyroid, honeycomb, Archimedean chords), infill ratio (10%, 20%, 30%, and 40%), wall thickness (0.8, 1.2, 1.6, and 2.0 mm), and inner diameter parameters. The structures designed using Taguchi L16 orthogonal design are printed with PLA material using FDM technology and evaluated by quasi-static compression tests. Peak crushing force (PCF), energy absorption (EA), and specific energy absorption (SEA) criteria are used to analyse crashworthiness performance. The experimental results showed that EA improves as the infill rate increases, but the gain decreases as the infill rate approaches 40% (SEA at 30% is better than that at 40%). By visualising the PCF and EA data relative to the utopia point (the lowest PCF and highest EA), GRID_T16F30D24, HCOMB_T08F30D22, and GRID_T12F20D22 are found to be the best-performing tubes. The grid and honeycomb infill types showed superiority at 20–30% infill rates and similar wall thicknesses. The Archimedean chords type performed poorly due to its tendency to fracture. Full article
(This article belongs to the Special Issue Bionic Design & Lightweight Engineering 2025)
Show Figures

Figure 1

23 pages, 508 KB  
Review
Chemical Crosslinking of Acid Soluble Collagen Fibres
by Peter Schyra, Dilbar Aibibu, Bernd Sundag and Chokri Cherif
Biomimetics 2025, 10(10), 701; https://doi.org/10.3390/biomimetics10100701 - 15 Oct 2025
Cited by 8 | Viewed by 3299
Abstract
Collagen, as the predominant structural protein in vertebrates, represents a promising biomimetic material for scaffold development. Fibre-based scaffolds produced through textile technologies enable precise modulation of structural characteristics to closely mimic the extracellular matrix architecture using wet-spun collagen fibres. However, this in vitro [...] Read more.
Collagen, as the predominant structural protein in vertebrates, represents a promising biomimetic material for scaffold development. Fibre-based scaffolds produced through textile technologies enable precise modulation of structural characteristics to closely mimic the extracellular matrix architecture using wet-spun collagen fibres. However, this in vitro fibre formation lacks natural crosslinking, resulting in collagen fibres with compromised mechanical strength, enzymatic resistance, and thermal stability compared to their native counterparts, thus restricting their biomedical applicability. Post-fabrication crosslinking is therefore imperative to enhance the durability and functional performance of collagen fibre-based scaffolds. Although traditional crosslinkers like glutaraldehyde effectively improve mechanical strength and stability, their clinical utility is hindered by cytotoxicity and associated adverse biological responses. Alternative synthetic crosslinking agents, such as hexamethylene diisocyanate, 1-Ethyl-3-(3’-dimethyl amino propyl) carbodiimide, and 1,4-Butanediol diglycidyl ether, have demonstrated superior cytocompatibility while effectively improving collagen fibre properties. Nonetheless, synthetic compounds may induce more pronounced foreign body reaction than natural agents, necessitating further investigation into their cytocompatibility across varying concentrations. In contrast, plant-based crosslinking offers a promising, cytocompatible alternative, significantly enhancing the thermal and mechanical stability of collagen fibres, provided that potential fibre discolouration is acceptable for intended biomedical applications. Full article
(This article belongs to the Section Biomimetics of Materials and Structures)
Show Figures

Figure 1

15 pages, 3846 KB  
Article
Optimizing Biodegradable Poly(D,L-lactide) Scaffolds Reinforced with Graphene Oxide for Bone Tissue Regeneration
by Esperanza Díaz, Ander García, Xabier León, Yolanda Merodio, Sylvie Ribeiro and Senentxu Lanceros-Méndez
Biomimetics 2025, 10(10), 700; https://doi.org/10.3390/biomimetics10100700 - 15 Oct 2025
Cited by 2 | Viewed by 1493
Abstract
This study investigates the potential of porous poly(D,L-lactide) (PDLLA) scaffolds reinforced with graphene oxide (GO) for bone tissue engineering applications. Scaffolds were fabricated using thermally induced phase separation (TIPS) and characterized in terms of morphology, biodegradation, thermal and mechanical properties, and cytocompatibility. The [...] Read more.
This study investigates the potential of porous poly(D,L-lactide) (PDLLA) scaffolds reinforced with graphene oxide (GO) for bone tissue engineering applications. Scaffolds were fabricated using thermally induced phase separation (TIPS) and characterized in terms of morphology, biodegradation, thermal and mechanical properties, and cytocompatibility. The incorporation of GO enhanced both mechanical strength and thermal stability, likely due to hydrogen bonding and electrostatic interactions between GO’s functional groups (carbonyl, carboxyl, epoxide, and hydroxyl) and PDLLA chains. In vitro degradation studies showed that GO accelerated degradation, while scaffolds with higher GO content retained superior mechanical strength. Cytotoxicity assays confirmed the biocompatibility of all scaffold variants, supporting their suitability for biomedical applications. Overall, the findings demonstrate how GO incorporation can modulate scaffold composition and performance. This provides insights for the design of improved systems for bone tissue regeneration. Full article
(This article belongs to the Special Issue Biomimicry and Functional Materials: 5th Edition)
Show Figures

Figure 1

20 pages, 2616 KB  
Article
Biomimetic Transfer Learning-Based Complex Gastrointestinal Polyp Classification
by Daniela-Maria Cristea, Daniela Onita and Laszlo Barna Iantovics
Biomimetics 2025, 10(10), 699; https://doi.org/10.3390/biomimetics10100699 - 15 Oct 2025
Cited by 6 | Viewed by 1145
Abstract
(1) Background: This research investigates the application of Artificial Intelligence (AI), particularly biomimetic convolutional neural networks (CNNs), for the automatic classification of gastrointestinal (GI) polyps in endoscopic images. The study combines AI and Transfer learning techniques to support early detection of colorectal cancer [...] Read more.
(1) Background: This research investigates the application of Artificial Intelligence (AI), particularly biomimetic convolutional neural networks (CNNs), for the automatic classification of gastrointestinal (GI) polyps in endoscopic images. The study combines AI and Transfer learning techniques to support early detection of colorectal cancer by enhancing diagnostic accuracy with pre-trained models; (2) Methods: The Kvasir dataset, comprising 4000 annotated endoscopic images across eight polyp categories, was used. Images were pre-processed via normalisation, resizing, and data augmentation. Several CNN architectures, including state-of-the-art optimized ResNet50, DenseNet121, and MobileNetV2, were trained and evaluated. Models were assessed through training, validation, and testing phases, using performance metrics such as overall accuracy, confusion matrix, precision, recall, and F1 score; (3) Results: ResNet50 achieved the highest validation accuracy at 90.5%, followed closely by DenseNet121 with 87.5% and MobileNetV2 with 86.5%. The models demonstrated good generalisation, with small differences between training and validation accuracy. The average inference time was under 0.5 s on a computer with limited resources, confirming real-time applicability. Confusion matrix analysis indicates that common errors frequently occur between visually similar classes, particularly when reviewed by less-experienced medical physicians. These errors underscore the difficulty of distinguishing subtle features in gastrointestinal imagery and highlight the value of model-assisted diagnostics; (4) Conclusions: The obtained results confirm that Deep learning-based CNN architectures, combined with Transfer learning and optimisation techniques, can classify accurately endoscopic images and support medical diagnostics. Full article
(This article belongs to the Special Issue Bio-Inspired Artificial Intelligence in Healthcare)
Show Figures

Figure 1

12 pages, 262 KB  
Article
Bioinspired Functional Design for Wearable Environmental Sensors
by Haejin Bae
Biomimetics 2025, 10(10), 698; https://doi.org/10.3390/biomimetics10100698 - 15 Oct 2025
Cited by 1 | Viewed by 1788
Abstract
Biological mechanisms observed across diverse species—such as adhesion, color change, antifouling, and flexible protection—are functionally classified to inform a principle-based conceptual framework for the design of wearable environmental sensors. Existing wearable sensors are constrained by poor skin conformity, reliance on chemical adhesives, performance [...] Read more.
Biological mechanisms observed across diverse species—such as adhesion, color change, antifouling, and flexible protection—are functionally classified to inform a principle-based conceptual framework for the design of wearable environmental sensors. Existing wearable sensors are constrained by poor skin conformity, reliance on chemical adhesives, performance degradation in wet environments, dependency on external power, and low durability. In response, biological case studies are systematically organized into four functional categories—reversible and wet adhesion, power-free coloration, antifouling and antibacterial surface mechanisms, and compliant protective architectures—and hierarchically mapped to corresponding engineering layers. Rather than reporting experimental results, this framework outlines how biological mechanisms was translated into structured design principles that collectively address the core requirements of wearable sensors: skin compatibility, energy efficiency, fouling resistance, and durability under mechanical deformation. Unlike previous biomimetic surveys that primarily catalog natural phenomena, this work establishes a structured, function-oriented framework that explicitly connects biological strategies to multilayer sensor architectures aligned with Nature-based Solutions and the Global Biodiversity Framework. Ultimately, it clarifies a unique conceptual pathway for sustainable, biodiversity-informed engineering design. Full article
(This article belongs to the Section Bioinspired Sensorics, Information Processing and Control)
19 pages, 7895 KB  
Article
SpiKon-E: Hybrid Soft Artificial Muscle Control Using Hardware Spiking Neural Network
by Florian-Alexandru Brașoveanu, Mircea Hulea and Adrian Burlacu
Biomimetics 2025, 10(10), 697; https://doi.org/10.3390/biomimetics10100697 - 15 Oct 2025
Viewed by 1662
Abstract
Artificial muscles play a key role in the future of humanoid robotics and medical devices, with research on wire-driven joints leading the field. While electric servo motors were once at the forefront, the focus has shifted toward materials that react to changes in [...] Read more.
Artificial muscles play a key role in the future of humanoid robotics and medical devices, with research on wire-driven joints leading the field. While electric servo motors were once at the forefront, the focus has shifted toward materials that react to changes in the environment (smart materials), including pneumatic silicone actuators and temperature-reactive metallic alloys, aiming to replicate human muscle actuation for improved performance. Initially designed for rigid actuators, control strategies were adapted to address the unique dynamics of artificial muscles. Although current controllers offer satisfactory performance, further optimization is necessary to mimic natural muscle control more rigorously. This study details the design and implementation of a novel system that mimics biological muscle. This system is designed to replicate the full range of motion and control functionalities, which can be utilized in various applications. This research has three significant contributions in the field of sustainable soft robotics. First, a novel shape memory alloy-based linear actuator is introduced, which achieves significantly higher displacements compared to traditional SMA wire-driven systems through a guiding mechanism. Second, this linear actuator is integrated into a hybrid soft actuation structure, which features a silicone PneuNet as the end effector and a force sensor for real-time pressure feedback. Lastly, a hardware Spiking Neural Network (HW-SNN) is utilized to control the exhibited force at the actuator’s endpoint. Experimental results showed that the displacement with the control system is significantly higher than that of the traditional control-based shape memory alloy systems. The system evaluation demonstrates good performance, thus advancing actuation and control in humanoid robotics. Full article
Show Figures

Figure 1

22 pages, 2258 KB  
Article
Designing Light for Emotion: A Neurophysiological Approach to Modeling Affective Responses to the Interplay of Color and Illuminance
by Xuejiao Li, Ruili Wang and Mincheol Whang
Biomimetics 2025, 10(10), 696; https://doi.org/10.3390/biomimetics10100696 - 14 Oct 2025
Cited by 10 | Viewed by 4820
Abstract
As the influence of indoor environments on human emotional regulation and cognitive function becomes increasingly critical in modern society, there is a growing need for intelligent lighting systems that dynamically respond to users’ emotional states. While previous studies have investigated either illuminance or [...] Read more.
As the influence of indoor environments on human emotional regulation and cognitive function becomes increasingly critical in modern society, there is a growing need for intelligent lighting systems that dynamically respond to users’ emotional states. While previous studies have investigated either illuminance or color in isolation, this study concentrates on quantitatively analyzing the interaction of these two key elements on human emotion and cognitive control capabilities. Utilizing electroencephalography (EEG) and electrocardiography (ECG) signals, we measured participants’ physiological responses and subjective emotional assessments in 18 unique lighting conditions, combining six colors and three levels of illuminance. The results confirmed that the interaction between light color and illuminance significantly affects physiological indicators related to emotion regulation. Notably, low-illuminance purple lighting was found to promote positive emotions and inhibit negative ones by increasing frontal alpha asymmetry (FAA) and gamma wave activity. Conversely, low-illuminance environments generally diminished cognitive reappraisal and negative emotion inhibition capabilities. Furthermore, a random forest model integrating time-series data from EEG and ECG predicted emotional valence and arousal with accuracies of 87% and 79%, respectively, demonstrating the validity of multi-modal physiological signal-based emotion prediction. This study provides empirical data and a theoretical foundation for the development of human-centered, emotion-adaptive lighting systems by presenting a quantitative causal model linking lighting, physiological responses, and emotion. These findings also provide a biomimetic perspective by linking lighting-induced physiological responses with emotion regulation, offering a foundation for the development of adaptive lighting systems that emulate natural light–human interactions. Full article
Show Figures

Figure 1

28 pages, 2869 KB  
Review
Scaffolds Mimicking the Tumor Microenvironment for In Vitro Malignancy Models
by Elisabetta Rosellini and Maria Grazia Cascone
Biomimetics 2025, 10(10), 695; https://doi.org/10.3390/biomimetics10100695 - 14 Oct 2025
Cited by 4 | Viewed by 2620
Abstract
The tumor microenvironment (TME) plays a crucial role in regulating cancer cell proliferation, invasion, and drug resistance. Traditional two-dimensional (2D) in vitro models and animal models often fail to replicate the biochemical and biophysical complexity of human tumors, leading to low predictive power [...] Read more.
The tumor microenvironment (TME) plays a crucial role in regulating cancer cell proliferation, invasion, and drug resistance. Traditional two-dimensional (2D) in vitro models and animal models often fail to replicate the biochemical and biophysical complexity of human tumors, leading to low predictive power in preclinical drug screening. In recent years, scaffold-based three-dimensional (3D) in vitro models have emerged as promising alternatives, offering a more physiologically relevant context for studying tumor behavior. Among these, biomimetic scaffolds capable of replicating the composition, stiffness, porosity, and signaling features of the tumor extracellular matrix (ECM) are of particular interest. This review provides a comprehensive overview of scaffold-based approaches for mimicking the TME in vitro. After outlining the key characteristics of the tumor ECM, we discuss various scaffold typologies, including those based on natural, synthetic, and hybrid biomaterials, as well as decellularized ECM. Recent advancements in fabrication technologies, such as electrospinning and 3D bioprinting, are also highlighted for their role in replicating the geometric and mechanical features of tumor tissues. Special attention is given to the integration of vascular components and stromal cells to recapitulate the complexity of the TME. Finally, we explore current limitations and future directions, emphasizing the need for standardized and reproducible models, particularly in the context of personalized cancer therapy. Full article
Show Figures

Figure 1

17 pages, 1444 KB  
Article
Self-Consistent Field Modeling of Bottle-Brush with Aggrecan-like Side Chain
by Ivan V. Mikhailov, Ivan V. Lukiev, Ekaterina B. Zhulina and Oleg V. Borisov
Biomimetics 2025, 10(10), 694; https://doi.org/10.3390/biomimetics10100694 - 14 Oct 2025
Viewed by 874
Abstract
Bottle-brush polymers with aggrecan-like side chains represent a class of biomimetic macromolecules that replicate key structural and functional features of natural complexes of aggrecans with hyaluronic acid (HA) which are the major components of articular cartilage. In this study, we employ numerical self-consistent [...] Read more.
Bottle-brush polymers with aggrecan-like side chains represent a class of biomimetic macromolecules that replicate key structural and functional features of natural complexes of aggrecans with hyaluronic acid (HA) which are the major components of articular cartilage. In this study, we employ numerical self-consistent field (SCF) modeling combined with analytical theory to investigate the conformational properties of cylindrical molecular bottle-brushes composed of aggrecan-like double-comb side chains tethered to the main chain (the backbone of the bottle-brush). We demonstrate that the architecture of the brush-forming double-comb chains and, in particular, the distribution of polymer mass between the root and peripheral domains significantly influences the spatial distribution of primary side chain ends, leading to formation of a “dead” zone near the backbone of the bottle-brush and non-uniform density profiles. The axial stretching force imposed by grafted double-combs in the main chain, as well as normal force acting at the junction point between the bottle-brush backbone and the double-comb side chain are shown to depend strongly on the side-chain architecture. Furthermore, we analyze the induced bending rigidity and persistence length of the bottle-brush, revealing that while the overall scaling behavior follows established power laws, the internal structure can be finely tuned without altering the backbone stiffness. These theoretical findings provide valuable insights into relations between architecture and properties of bottle-brush-like supra-biomolecular structures, such as aggrecan-hyaluronan complexes. Full article
(This article belongs to the Special Issue Design and Fabrication of Biomimetic Smart Materials)
Show Figures

Figure 1

14 pages, 1197 KB  
Article
An Inclusive Offline Learning Platform Integrating Gesture Recognition and Local AI Models
by Marius-Valentin Drăgoi, Ionuț Nisipeanu, Roxana-Adriana Puiu, Florentina-Geanina Tache, Teodora-Mihaela Spiridon-Mocioacă, Alexandru Hank and Cozmin Cristoiu
Biomimetics 2025, 10(10), 693; https://doi.org/10.3390/biomimetics10100693 - 14 Oct 2025
Cited by 10 | Viewed by 1756
Abstract
This paper introduces a gesture-controlled conversational interface driven by a local AI model, aimed at improving accessibility and facilitating hands-free interaction within digital environments. The technology utilizes real-time hand gesture recognition via a typical laptop camera and connects with a local AI engine [...] Read more.
This paper introduces a gesture-controlled conversational interface driven by a local AI model, aimed at improving accessibility and facilitating hands-free interaction within digital environments. The technology utilizes real-time hand gesture recognition via a typical laptop camera and connects with a local AI engine to produce customized learning materials. Users can peruse educational documents, obtain topic summaries, and generate automated quizzes with intuitive gestures, including lateral finger movements, a two-finger gesture, or an open palm, without the need for conventional input devices. Upon selection of a file, the AI model analyzes its whole content, producing a structured summary and a multiple-choice assessment, both of which are immediately saved for subsequent inspection. A unified set of gestures facilitates seamless navigating within the user interface and the opened documents. The system underwent testing with university students and faculty (n = 31), utilizing assessment measures such as gesture detection accuracy, command-response latency, and user satisfaction. The findings demonstrate that the system offers a seamless, hands-free user experience with significant potential for usage in accessibility, human–computer interaction, and intelligent interface design. This work advances the creation of multimodal AI-driven educational aids, providing a pragmatic framework for gesture-based document navigation and intelligent content enhancement. Full article
(This article belongs to the Special Issue Biomimicry for Optimization, Control, and Automation: 3rd Edition)
Show Figures

Figure 1

32 pages, 17162 KB  
Article
A Novel Proposal for a Bladeless Wind Turbine: Bio-Inspired Design of a Columnar-Cactus Type Mast
by Isaac Hernández-Arriaga, Joaquín Pérez-Meneses, Guillermo Eduardo Mejía-Hernández, Juventino López-Barroso, Cynthia Graciela Flores-Hernández and Daniel Hernández-Arriaga
Biomimetics 2025, 10(10), 692; https://doi.org/10.3390/biomimetics10100692 - 14 Oct 2025
Cited by 1 | Viewed by 1792
Abstract
This research presents an experimental study on a scaled prototype of a bladeless wind turbine that operates based on the principle of vortex-induced vibrations (VIV-BWT) with the implementation of bio-inspired design of a columnar-cactus type mast. The aerodynamic performance of columnar-cactus type masts [...] Read more.
This research presents an experimental study on a scaled prototype of a bladeless wind turbine that operates based on the principle of vortex-induced vibrations (VIV-BWT) with the implementation of bio-inspired design of a columnar-cactus type mast. The aerodynamic performance of columnar-cactus type masts with different numbers of ribs was investigated and compared with that of a conventional cylindrical mast. The objective of this novel proposal is to maximize wind energy conversion efficiency through vortex-induced vibrations, thereby enhancing energy generation. The present study focuses on the geometry of the columnar-cactus type mast as a vortex generator, which significantly influences the performance of this type of VIV wind energy harvester. The findings reveal that the geometric configuration of the cactus-inspired mast and the mast angle promote vortex formation, leading to higher lift coefficients and forces. Consequently, this results in greater vortex-induced vibration magnitudes. For instance, at a wind speed of 6.0 m/s and a mast angle of 0°, the 6-rib cactus-type mast exhibits 12 times greater VIV amplitude compared to the conventional cylindrical mast, while the 5-rib and 7-rib cactus-type masts show 2.4- and 2.2-times greater amplitudes, respectively. However, for wind speeds below 5 m/s, the cylindrical mast demonstrates superior VIV performance. Full article
Show Figures

Graphical abstract

15 pages, 858 KB  
Article
Efficacy and Safety of Kahook Dual Blade Goniotomy and Trabecular Micro-Bypass Stent in Combination with Cataract Extraction
by Kevin Y. Wu, Shu Yu Qian, Lysa Houadj and Michael Marchand
Biomimetics 2025, 10(10), 691; https://doi.org/10.3390/biomimetics10100691 - 14 Oct 2025
Cited by 2 | Viewed by 1634
Abstract
In recent years, rapid advancements in glaucoma research have led to the development of more effective treatments of this chronic and irreversible condition. Of these, Kahook Blade Dual (KDB) goniotomy and second-generation trabecular micro-bypass stent (iStent) are two novel biomimetic procedures which have [...] Read more.
In recent years, rapid advancements in glaucoma research have led to the development of more effective treatments of this chronic and irreversible condition. Of these, Kahook Blade Dual (KDB) goniotomy and second-generation trabecular micro-bypass stent (iStent) are two novel biomimetic procedures which have designs inspired by the eye’s natural drainage mechanisms. In this retrospective study, we evaluated the safety and effectiveness of both surgeries by including 176 eyes from 110 patients: 142 eyes in the iStent group and 34 in the KDB group. The primary outcomes of this study were the proportions of patients in each group attaining a 20% reduction in IOP and a post-operative IOP < 19 mmHg. At the last follow-up, a 20% reduction in IOP was achieved by 67% of iStent inject patients and 50% of KDB patients (p = 0.07). The iStent group also showed a higher proportion of patients reaching an IOP of less than 19 mmHg (81% vs. 71% in the KDB group, p = 0.13). The number of medications did not decrease in either group from pre-op to the last follow-up. The KDB group had more failures (29.4% vs. 4.2%) and a significantly higher adverse event rate than the iStent inject group (47.1% vs 12.0%). Full article
Show Figures

Figure 1

44 pages, 49738 KB  
Article
A Hybrid SAO and RIME Optimizer for Global Optimization and Cloud Task Scheduling
by Ming Zhu, Jing Li and Xiao Yang
Biomimetics 2025, 10(10), 690; https://doi.org/10.3390/biomimetics10100690 - 13 Oct 2025
Cited by 2 | Viewed by 1264
Abstract
In a global industrial landscape where the digital economy accounts for over 40% of total output, cloud computing technology is reshaping business models at a compound annual growth rate of 19%. This trend has led to an increasing number of cloud computing tasks [...] Read more.
In a global industrial landscape where the digital economy accounts for over 40% of total output, cloud computing technology is reshaping business models at a compound annual growth rate of 19%. This trend has led to an increasing number of cloud computing tasks requiring timely processing. However, most computational tasks are latency-sensitive and cannot tolerate significant delays. This has led to the urgent need for researchers to address the challenge of effectively scheduling cloud computing tasks. This paper proposes a hybrid SAO and RIME optimizer (HSAO) for global optimization and cloud task scheduling problems. First, population initialization based on ecological niche differentiation is proposed to enhance the initial population quality of SAO, enabling it to better explore the solution space. Then, the introduction of the soft frost search strategy and hard frost piercing mechanism from the RIME optimization algorithm enables the algorithm to better escape local optima and accelerate its convergence. Additionally, a population-based collaborative boundary control method is proposed to handle outlier individuals, preventing them from clustering at the boundary and enabling more effective exploration of the solution space. To evaluate the effectiveness of the proposed algorithm, we compared it with 11 other algorithms using the IEEE CEC2017 test set and assessed the differences through statistical analysis. Experimental data demonstrate that the HSAO algorithm exhibits significant advantages. Furthermore, to validate its practical applicability, we applied HSAO to real-world cloud computing task scheduling problems, achieving excellent results and successfully completing the scheduling planning of cloud computing tasks. Full article
(This article belongs to the Special Issue Exploration of Bio-Inspired Computing: 2nd Edition)
Show Figures

Figure 1

22 pages, 3034 KB  
Review
Multifunctional Liposomes: Smart Nanomaterials for Enhanced Photodynamic Therapy
by Ji-Won Yu, Do Gyun Kim and Gi Doo Cha
Biomimetics 2025, 10(10), 689; https://doi.org/10.3390/biomimetics10100689 - 13 Oct 2025
Cited by 4 | Viewed by 2181
Abstract
Cancer remains one of the leading causes of mortality worldwide and continues to pose significant therapeutic challenges despite decades of research. Conventional treatments such as chemotherapy and radiotherapy often lack selectivity, damaging both malignant and healthy tissues and resulting in severe side effects. [...] Read more.
Cancer remains one of the leading causes of mortality worldwide and continues to pose significant therapeutic challenges despite decades of research. Conventional treatments such as chemotherapy and radiotherapy often lack selectivity, damaging both malignant and healthy tissues and resulting in severe side effects. Photodynamic therapy (PDT) has emerged as a promising non-invasive alternative that selectively eradicates cancer cells or pathogens using a photosensitizer (PS), light, and oxygen. PDT induces necrosis or apoptosis in cancer cells by locally generating cytotoxic reactive oxygen species through targeted laser irradiation. However, its clinical efficacy is limited by factors such as tumor hypoxia, poor PS delivery efficiency, and light attenuation within biological tissues. Recent advances in liposomal nanoplatforms have shown considerable potential in overcoming these barriers. Liposomes can co-deliver PS, therapeutic agents, and oxygen, thereby enhancing PDT outcomes. This review outlines the fundamental principles of PDT and the physicochemical properties of liposomes. It then explores two major strategies for improving PDT efficacy using liposomes: PS-drug co-delivery and oxygen delivery to mitigate tumor hypoxia for synergistic therapeutic effects. Finally, current limitations and future perspectives of liposome-based nanomedicine in photodynamic cancer therapy are discussed. Overall, this review provides a foundation for advancing liposome-based strategies toward clinical implementation in photodynamic cancer treatment. Full article
Show Figures

Figure 1

26 pages, 4381 KB  
Article
Biocomposite-Based Biomimetic Plate for Alternative Fixation of Proximal Humerus Fractures
by Miguel Suffo, Irene Fernández-Illescas, Ana María Simonet, Celia Pérez-Muñoz and Pablo Andrés-Cano
Biomimetics 2025, 10(10), 688; https://doi.org/10.3390/biomimetics10100688 - 13 Oct 2025
Cited by 1 | Viewed by 1422
Abstract
Proximal humerus fractures are frequent injuries that often require internal fixation. Conventional metallic plates, however, present significant drawbacks such as corrosion, secondary removal surgeries, and adverse reactions in patients with metal hypersensitivity. This study evaluates biocomposite plates fabricated from polylactic acid (PLA) and [...] Read more.
Proximal humerus fractures are frequent injuries that often require internal fixation. Conventional metallic plates, however, present significant drawbacks such as corrosion, secondary removal surgeries, and adverse reactions in patients with metal hypersensitivity. This study evaluates biocomposite plates fabricated from polylactic acid (PLA) and polyvinyl alcohol (PVA), reinforced with hydroxyapatite (HA) derived from sugar industry by-products (BCF) at 10% and 20% concentrations. These composites are compatible with both injection molding and 3D printing, enabling the design of patient-specific implants. Characterization by SEM, FTIR, XRD, and DSC confirmed that BCF incorporation enhances strength, stiffness, osteoconductivity, and biocompatibility. Mechanical testing showed that PVA/BCF exhibited greater tensile strength and stiffness, suggesting suitability for load-bearing applications, though their water solubility restricts use in humid environments and prevents filament-based 3D printing. PLA/BCF composites demonstrated better processability, favorable mechanical performance, and compatibility with both manufacturing routes. Finite element analysis highlighted the importance of plate–humerus contact in stress distribution and fixation stability. Compared with non-biodegradable thermoplastics such as PEI and PEEK, PLA/BCF and PVA/BCF offer the additional advantage of controlled biodegradation, reducing the need for secondary surgeries. Cell viability assays confirmed cytocompatibility, with optimal outcomes at 10% BCF in PVA and 20% in PLA. These results position PLA/BCF and PVA/BCF as sustainable, patient-tailored alternatives to metallic implants, combining adequate mechanical support with bone regeneration potential. Full article
(This article belongs to the Special Issue Biomimetic Materials for Bone Tissue Engineering)
Show Figures

Figure 1

16 pages, 758 KB  
Article
Real-Time Robust Path Following of a Biomimetic Robotic Dolphin in Disturbance-Rich Underwater Environments
by Yukai Feng, Sijie Li, Zhengxing Wu, Junzhi Yu and Min Tan
Biomimetics 2025, 10(10), 687; https://doi.org/10.3390/biomimetics10100687 - 13 Oct 2025
Cited by 1 | Viewed by 1482
Abstract
In ocean engineering, path following serves as a fundamental capability for autonomous underwater vehicles (AUVs), enabling essential operations such as environmental exploration and inspection. However, for robotic dolphins employing dorsoventral undulatory propulsion, the periodic pitching induces strong coupling between propulsion and attitude, posing [...] Read more.
In ocean engineering, path following serves as a fundamental capability for autonomous underwater vehicles (AUVs), enabling essential operations such as environmental exploration and inspection. However, for robotic dolphins employing dorsoventral undulatory propulsion, the periodic pitching induces strong coupling between propulsion and attitude, posing significant challenges for precise path following in disturbed environments. In this paper, a real-time robust path-following control framework is proposed for robotic dolphins to address these challenges. First, a novel robotic dolphin platform is presented by integrating a dorsoventral propulsion mechanism with a passive peduncle joint, followed by the systematic formulation of a full-state dynamic model. Then, a minimum-snap-based path optimizer is constructed to generate smooth and dynamically feasible trajectories, improving path quality and motion safety. Subsequently, a robust model predictive controller is developed, which incorporates control surface dynamics, a nonlinear disturbance observer, and a Sigmoid-based disturbance-grading mechanism to ensure fast attitude response and precise tracking performance. Finally, extensive simulations under various environmental disturbances validate the effectiveness of the proposed approach in both trajectory optimization and robust path following. The proposed framework not only demonstrates strong robustness in path following and disturbance rejection, but also provides practical guidance for future underwater missions such as long-term environmental monitoring, inspection, and rescue. Full article
(This article belongs to the Special Issue Bionic Robotic Fish: 2nd Edition)
Show Figures

Figure 1

19 pages, 20836 KB  
Article
Design and Flight Experiment of a Motor-Directly-Driven Flapping-Wing Micro Air Vehicle with Extension Springs
by Seungik Choi, Changyong Oh, Taesam Kang and Jungkeun Park
Biomimetics 2025, 10(10), 686; https://doi.org/10.3390/biomimetics10100686 - 12 Oct 2025
Cited by 3 | Viewed by 2071
Abstract
This study presents the design, control, and flight experiments of a motor-directly-driven flapping-wing micro air vehicle with extension springs (MDD-FWMAVES). The flapping wing actuation utilizes the resonance of a linear extension spring and a flapping wing. The analysis results of the proposed MDD-FWMAVES [...] Read more.
This study presents the design, control, and flight experiments of a motor-directly-driven flapping-wing micro air vehicle with extension springs (MDD-FWMAVES). The flapping wing actuation utilizes the resonance of a linear extension spring and a flapping wing. The analysis results of the proposed MDD-FWMAVES revealed a resonant frequency of 19.59 Hz for the flapping-wing mechanism, and actual flapping experiments confirmed this to be 20 Hz. Using a six-axis load cell, we demonstrated the ability to generate roll, pitch, and yaw moments for attitude control based on wing flapping variations. All roll, pitch, and yaw moments were linearly proportional to the wing flapping variations. MEMS gyroscopes and accelerometers were used to measure roll, pitch, and yaw angular velocities and the gravity. A complementary filter was applied to these measurements to obtain the roll and pitch angles required for attitude control. A microprocessor, two motor drive circuits, one MEMS gyroscope/accelerometer, and one EEPROM for flight data storage were implemented on a single, ultra-compact electronic control board and mounted on the MDD-FWMAVES. Simple roll and pitch PD controllers were implemented on this electronic control board, and the controlled flight feasibility of the MDD-FWMAVES was explored. Flight tests demonstrated stable hovering for approximately 6 s. While yaw control was not achieved, the onboard feedback control system demonstrated stable roll and pitch control. Therefore, the MDD-FWMAVES holds the potential to be developed into a high-performance flapping-wing micro air vehicle if its flight system and controller are improved. Full article
(This article belongs to the Special Issue Bio-Inspired Flight Systems and Bionic Aerodynamics 2.0)
Show Figures

Graphical abstract

39 pages, 1466 KB  
Article
Empirical Evaluation of an Elitist Replacement Strategy for Differential Evolution with Micro-Populations
by Irving Luna-Ortiz, Alejandro Rodríguez-Molina, Miguel Gabriel Villarreal-Cervantes, Mario Aldape-Pérez, Alam Gabriel Rojas-López and Jesús Aldo Paredes-Ballesteros
Biomimetics 2025, 10(10), 685; https://doi.org/10.3390/biomimetics10100685 - 12 Oct 2025
Cited by 2 | Viewed by 1025
Abstract
This paper introduces a variant of differential evolution with micro-populations, called μ-DE-ERM, which incorporates a periodic elitist replacement mechanism with the aim of preserving diversity without the need to measure it explicitly. The proposed algorithm is designed for scenarios with reduced evaluation [...] Read more.
This paper introduces a variant of differential evolution with micro-populations, called μ-DE-ERM, which incorporates a periodic elitist replacement mechanism with the aim of preserving diversity without the need to measure it explicitly. The proposed algorithm is designed for scenarios with reduced evaluation budgets, where efficiency and convergence stability are critical. Its performance is evaluated on CEC 2005 and CEC 2017 benchmark suites, covering unimodal, multimodal, hybrid, and composition functions, as well as on two real-world engineering problems: the identification of dynamic parameters and the tuning of a PID controller for a one-degree-of-freedom robotic manipulator. The comparative analysis shows that μ-DE-ERM achieves competitive or superior results against its predecessors DE and μ-DE, and remains effective when contrasted with advanced algorithms such as L-SHADE and RuGA. Furthermore, additional comparisons with algorithms with competitive replacement mechanisms, μ-DE-Cauchy and μ-DE-Shrink, confirm the robustness of the proposal in real applications, particularly under strict computational constraints. These findings support μ-DE-ERM as a practical and efficient alternative for optimization problems in resource-limited environments, delivering reliable solutions at low computational cost. Full article
(This article belongs to the Special Issue Exploration of Bio-Inspired Computing: 2nd Edition)
Show Figures

Figure 1

Previous Issue
Next Issue
Back to TopTop
