


Abstract
Let be the subgroup of fourth roots of unity inside , the multiplicative group of complex units. For a -gain graph , we introduce gain functions on its line graph and on its subdivision graph . The corresponding gain graphs and are defined up to switching equivalence and generalize the analogous constructions for signed graphs. We discuss some spectral properties of these graphs and in particular we establish the relationship between the Laplacian characteristic polynomial of a gain graph , and the adjacency characteristic polynomials of and . A suitably defined incidence matrix for -gain graphs plays an important role in this context.
1. Introduction
Let be a simple graph with the vertex set and the set of oriented edges that contains two copies of each edge of with opposite directions. We write for the oriented edge from to . Given any group , a (-)gain graph is a triple consisting of an underlying graph , the gain group and a map such that called the gain function.
Gain graphs (also known in the literature as voltage graphs) are studied in many, not necessarily pure mathematics, research areas (for more details, see [1] and the annotated bibliography [2]). During the last decade, there has been a growing interest for the study of matrices and eigenvalues associated to gain graphs. For instance, in [3], N. Reff studied some spectral properties of the adjacency and the Laplacian matrix of -graphs, where denotes the circle group, i.e., the multiplicative group of all complex numbers with norm 1. Such gain graphs are also known as complex unit gain graphs. In [4], the same author introduced a notion of orientation for gain graphs in order to provide a suitable setting to build up line graphs of gain graphs. This setting works reasonably well when is abelian. More recently, in [5], the third and the fourth authors of the present paper began to explore the spectral properties of -gain graphs, where denotes the group of the fourth roots of unity , showing in particular how the least Laplacian eigenvalue of a -gain graph is related to its frustration index and number. Other spectral results concerning are obtained in [6,7,8], where gain graphs are called weighted directed graphs (see also their list of references).
In this paper, we also investigate -gain graphs. The interest towards -gain graphs is due to the fact that every spectral result concerning -gain graphs applies as well to -gain graphs, which are well-known as signed graphs. In fact, the latter ones can be seen as -gain graph such that . Moreover, is the minimal complex unit gain context allowing to retrieve the spectral theory of digraphs and mixed graphs as developed, for instance, in [9]. In other words, digraphs and mixed graphs can be also seen as -gain graphs , such that .
The rest of the paper is organized as follows. In Section 2, we recall some background theory on gain graphs, including notions of balancedness and switching equivalence. In Section 3, we revisit the N. Reff’s notion of line graph associated to -gain graph emphasizing his results in the case . Finally, in Section 4, we introduce subdivision graphs determined by -gain graphs. To best of our knowledge, no attempts in the same direction have been done in the literature. Our constructions are consistent with those carried out for signed graphs in [10] (Section 2) (see also [11] (Section 2)).
2. Preliminaries
From now on, a -gain graph is simply denoted by . We write for the -gain graph with all neutral edges. The all-negative -gain graph is a gain graph such that maps all oriented edges onto . We say that a -gain graph is of order n and size m if its underlying graph has n vertices and m edges.
Moreover, we adopt the following notation
for the set of vertices and the set of (unoriented) edges of , respectively.
Let be the set of m times n complex matrices. For a matrix , we denote by its conjugate (or Hermitian) transpose; i.e., .
The adjacency matrix of a -gain graph is defined by
If is an arc from to , then . Consequently, is Hermitian and its eigenvalues are real. The Laplacian matrix is defined as , where stands for the diagonal matrix of vertex degrees of . Therefore, is also Hermitian. As shown in [3] by N. Reff, the matrix is positive semidefinite, and all its eigenvalues are nonnegative. The multiset of eigenvalues of (respectively, of ) is called the adjacency (respectively, the Laplacian) spectrum of and is denoted by (respectively, ). A switching function of a given gain graph is any map . In other words, the switching the -gain graph means replacing by , where and obtaining in this way the new -gain graph . We say that and (and their corresponding gain functions) are switching equivalent if there exists a switching function such that . By writing or , we mean that and are switching equivalent.
To each switching function , we associate a diagonal matrix also known as switching matrix. Note that
Hence, given any pair ) of switching equivalent -gain graphs, we get the following equality between their spectra:
One of the key notions in the theory of gain graphs (and of the more general theory of biased graphs as well) is balancedness (see [1]). An oriented edge is said to be neutral for if . Similarly, the walk is said to be neutral if its gain
is equal to 1. An edge set is said to be balanced if every directed cycle with edges in S is neutral. A subgraph is balanced if its edge set is balanced (see [3] and [5] for further details).
The following proposition gives necessary and sufficient conditions for a -gain graph to be balanced. It also holds in the more general context of complex unit gain graphs (see [5] for a proof).
Proposition 1.
Let be a -gain graph. Then, the following are equivalent:
- 1.
- Φ is balanced.
- 2.
- .
- 3.
- There exists a function such that
Although the following characterization of balanced -gain graph is not used in our paper, we recall by sake of completeness that a connected -gain graph is balanced if and only if its least Laplacian eigenvalue is 0. This follows by [3] (Lemma 2.1 (2)) or [12] (Theorem 2.8).
The next proposition restates the result of [4] (Lemma 2.2) in the case of -gain graphs.
Proposition 2.
Let and be -gain graphs with the same underlying graph Γ. If for every cycle C in Γ there exists a directed cycle with base vertex v such that , then there exists a switching function ζ such that .
By Proposition 2, it follows that a gain graph is balanced if and only if all its directed cycles are neutral. Moreover, if in , there exists a directed cycle with an imaginary gain, then cannot be switching equivalent to a signed graph.
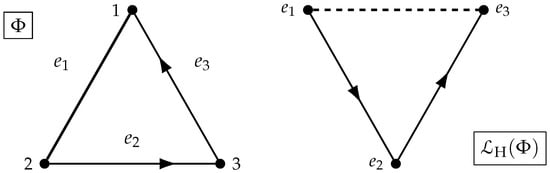
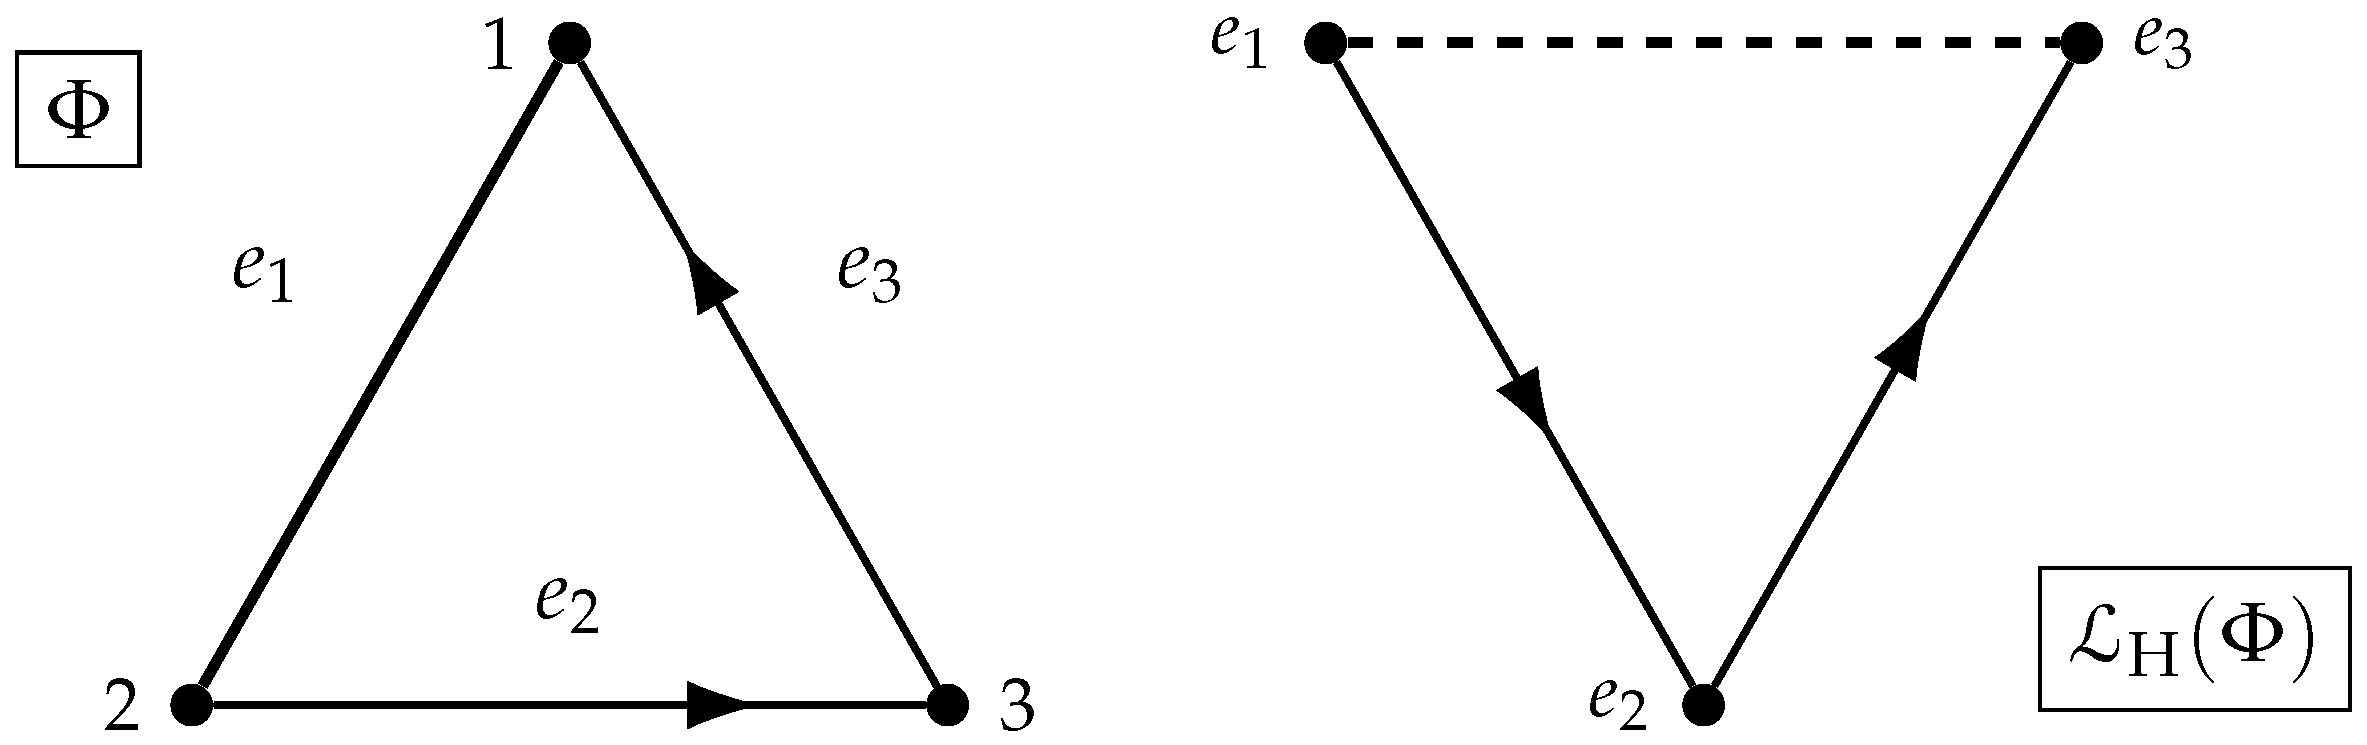
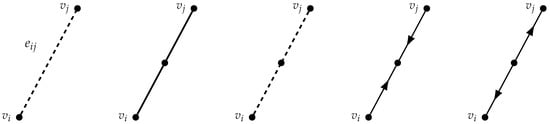
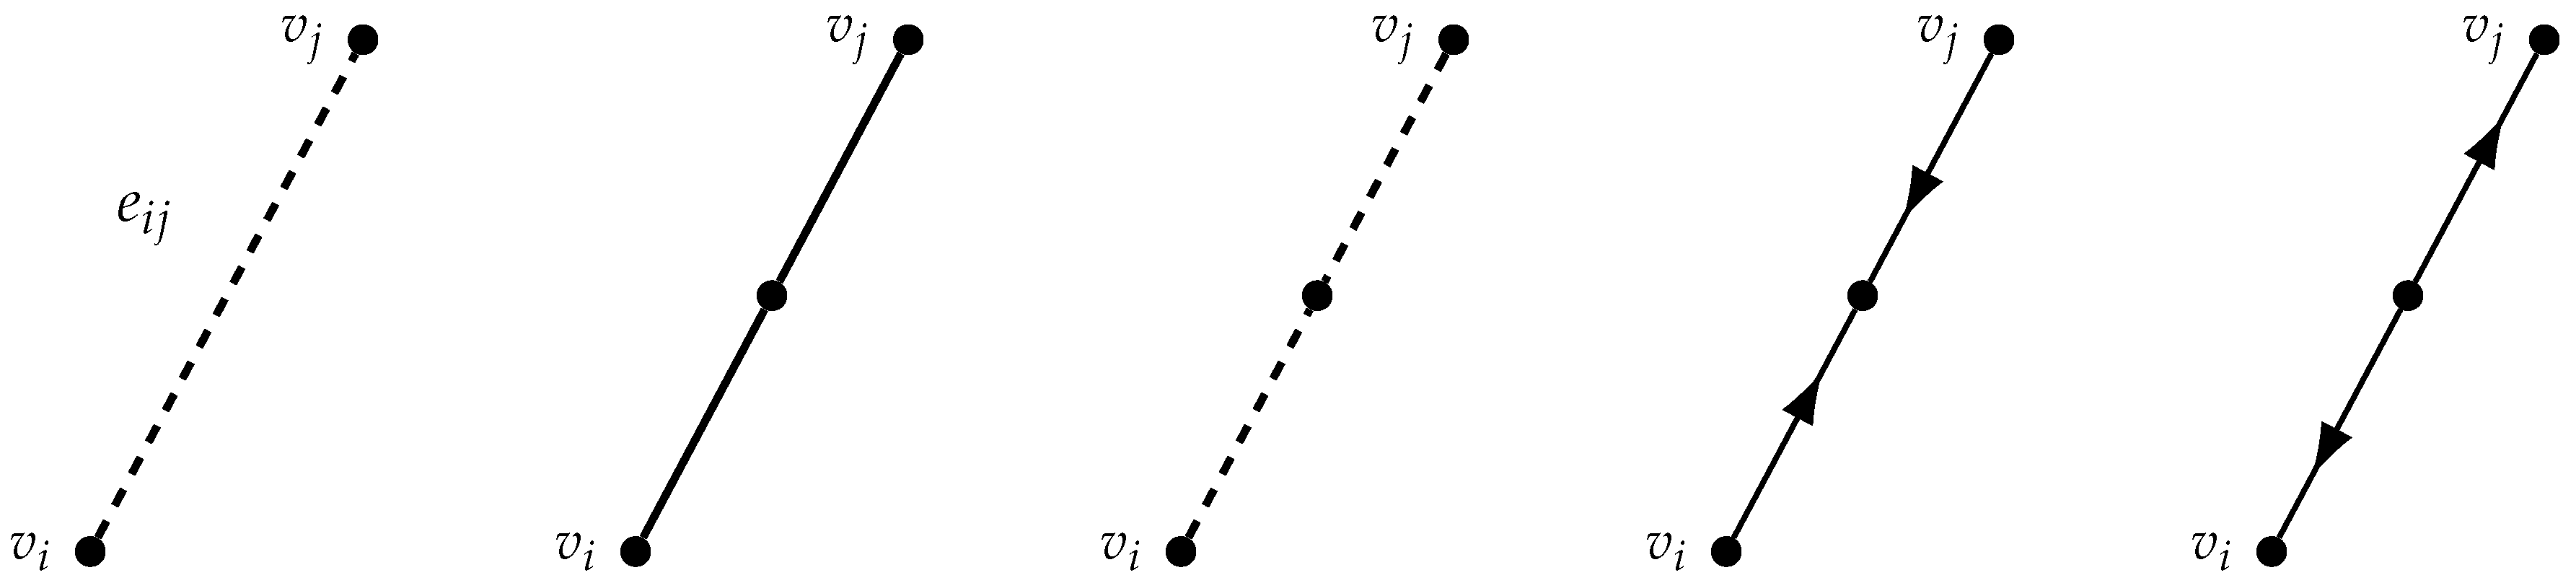
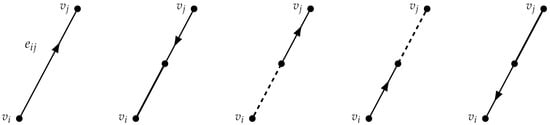
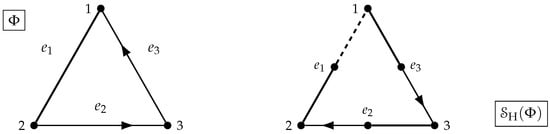
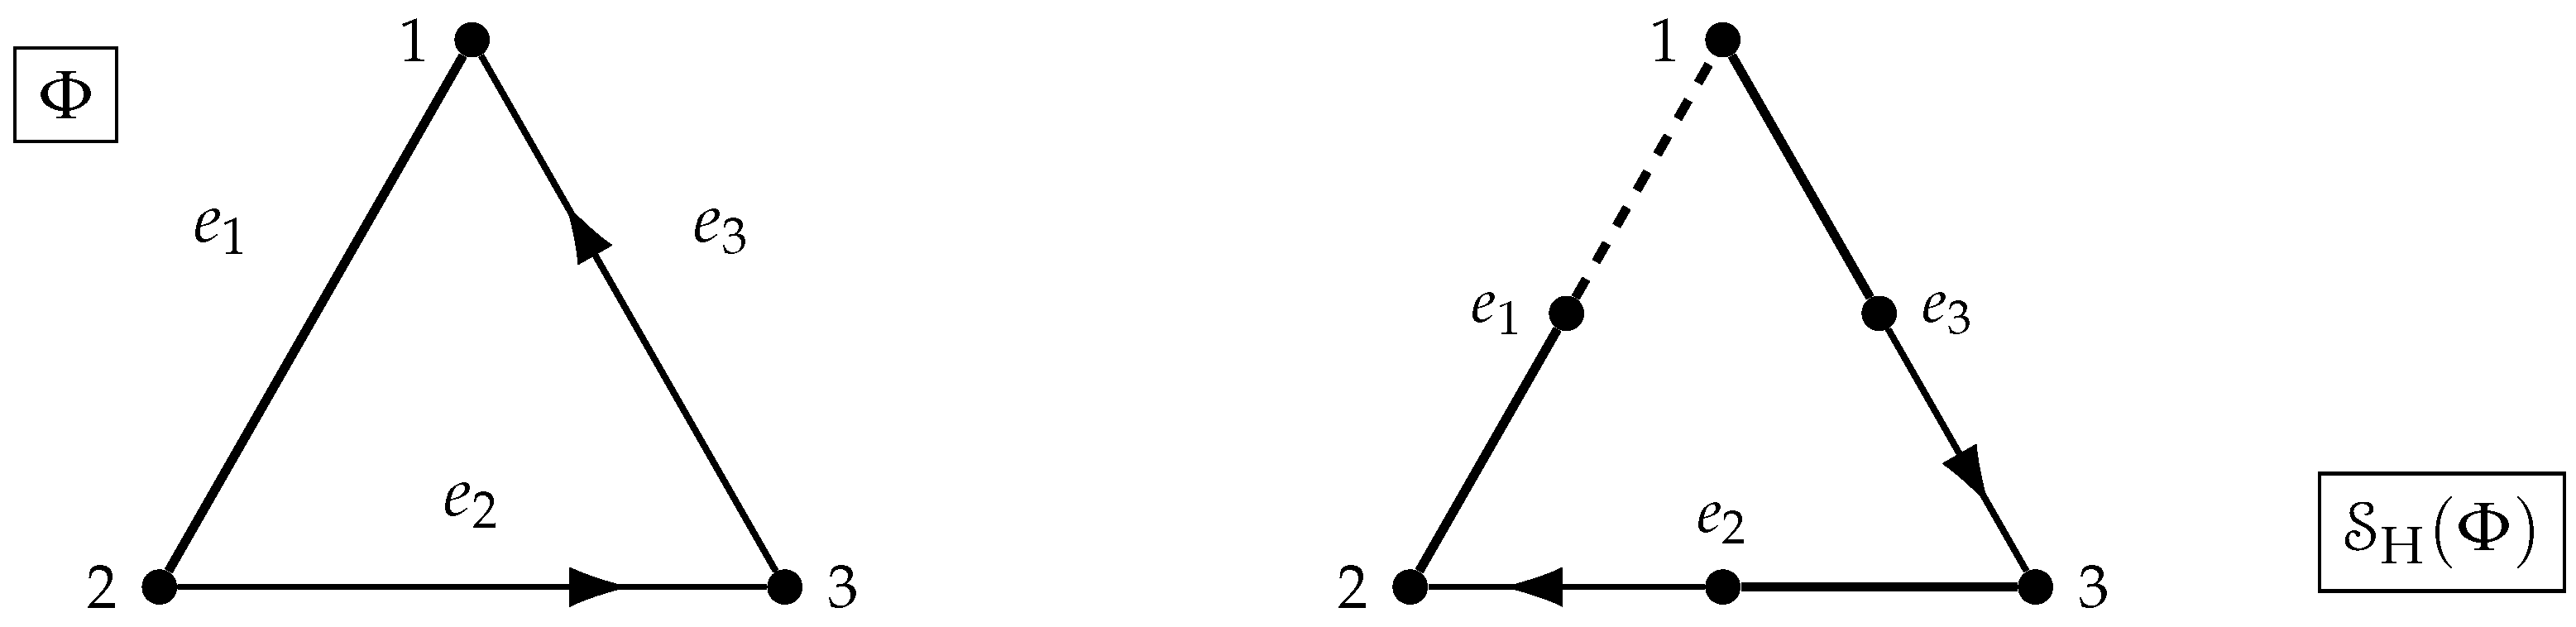
To depict -gain graphs in Figure 1, Figure 2, Figure 3, Figure 4 and Figure 5, each continuous (respectively, dashed) thick undirected line represents two opposite oriented edges with gain 1 (respectively, ), whereas the arrows detect the oriented edges ’s such that . The other possible choice for the arrow direction not employed here—namely using an arrow from v to u to denote the oriented edge such that —would lead to an alternative and fully satisfactory way to “read” the imaginary gains from the drawings.
Figure 1.
The unbalanced graph ) and its balanced line graph .
Figure 2.
Four possibilities for gains on the pair of edges in the subdivision graph corresponding to when .
Figure 3.
Four possibilities for gains on the pair of edges in the subdivision graph corresponding to when .
Figure 4.
Four possibilities for gains on the pair of edges in the subdivision graph corresponding to when .
Figure 5.
The graph ) and one of its subdivision graphs for an incidence matrix of .
3. Line Graphs Associated to -Gain Graphs
Recall that stands for the multiplicative group of all complex numbers with norm 1. In other words, is a subgroup of the multiplicative group of all nonzero complex numbers. Clearly, is a subgroup of .
We start with an elementary algebraic lemma. For its relevance in the sequel, we also provide its proof.
Lemma 1.
Let and be two pairs in such that
Then, there exists such that .
Proof of Lemma 1.
Let be a -gain graph. We say that the matrix with entries in is an incidence matrix of if
In the case when joins and , we also require that . We say “an” incidence matrix, because by this definition is unique only if is empty, i.e., if it is of size 0. If each column is multiplied by any element in the result will still be an incidence matrix. The next proposition shows that all the other possible incident matrices can be obtained from a fixed in that way.
Proposition 3.
Let and be two incidence matrices both related to the -gain graph . There exists an diagonal matrix S with entries in such that and .
Proof of Proposition 3.
Let and be the endpoints of a fixed edge . Clearly, the only non-zero elements in the hth columns of and are and , where
By Lemma 1, there exists a such that . For , it can be easily verified that and . □
In particular, by Proposition 3, for a fixed edge with endpoints and , we have four different possibilities for the corresponding column in the incidence matrix:
In other words, every -gain graph admits different incidence matrices related to it.
Proposition 4.
Let be an incidence matrix related to the -gain graph . Then
Proof of Proposition 4.
Let . By definition,
In fact, whenever , and there are precisely summands of this type in (4). If , then
where is 0 whenever and are not adjacent. This completes the proof. □
To have a lighter notation, in what follows, we denote by a specific incidence matrix related to the -gain graph . We next explain how determines a -gain structure on the line graph . It is well-known that and , whenever e and f share an endpoint. We denote by the -gain graph , where
where w is the endpoint shared by the edges e and f. It is easy to verify that is a gain function. In fact,
The proof of our Theorem 1 reads the same line as the one of [4] (Theorem 5.1).
Theorem 1.
Let be one of the incidence matrices related to the -gain graph . Then,
Proof of Theorem 1.
First, note that is an matrix. Consider next the dot product of row of with column of . We differ two cases:
- (same edge). Let u and w be the endpoints of . Then, and are the only non-zero entries in column . Therefore,
- By definition,In the last sum there is at most one non-zero summand, which actually exists if and only if and are adjacent in the line graph, i.e., when and share a common endpoint, say w. Hence, supposing ,
Now, the statement follows from Equation (5). □
Let be an abelian group. In [4], N. Reff already introduced a line graph associated to the gain graph . Its gains not only depend on the chosen incidence matrix, but also on the pick of a weak involution in , i.e., on an element such that . Our definition of is consistent with N. Reff’s for and . In the case when , i.e., when the -gain graph is actually a signed graph, with a gain function defined as in Equation (5), we retrieve the same signature on as assigned in [10] (Section 2) and [11] (Section 2). It is also possible to define the adjacency matrix of a line graph as . In that case the signature of the line graph is consistent to the one defined by T. Zaslavsky.
Proposition 5.
Let and be two incidence matrices both associated to the same -gain graph . Then, and share the same adjacency spectrum. Moreover, every gain graph which is switching equivalent to is a line graph associated to Φ.
Proof of Proposition 5.
By Proposition 3, there exists a diagonal matrix S with entries in such that and . Next by Equation (6):
This proves the first assertion.
Let now be a -gain graph, which is switching equivalent to . Then, there exists a map such that . For , it easily follows , where . □
By Proposition 5 line graphs associated to -gain graphs fully represent a class of switching equivalent gain graphs, similarly as the corresponding construction in the smaller context of signed graphs (see [10]).
Preservation of switching equivalence classes is often recognized as a minimum requirement to judge positively new constructions involving signed or gain graphs. Next, proposition shows that the introduced notion of line graph associated to a -gain graph is appropriate in this sense.
Proposition 6.
Line graphs of switching equivalent -gain graphs and are switching equivalent.
Proof of Proposition 6.
Let be a fixed incident matrix for . Since , there exists a map such that .
Suppose that and are the endpoint of the edge . By definition, we obtain
and consequently
It turns out that, for the switching matrix , the matrix is an incidence matrix of , and . In fact, if w is the endpoint shared by two edges e and f of ,
Hence, . Now, the proof follows by Proposition 5. □
The line graph of a balanced -gain graph does not have necessarily to be balanced, i.e., it may happen that is balanced while is not, as shown in the following example.
Example 1.
Let be the -gain graph depicted on the left in Figure 1. Since and then , thus the gain graph Φ is unbalanced. For the incident matrix of Φ
a direct calculation shows that
In addition,
which shows that the graph is balanced.
The following theorem gives a characterization of -gain graphs whose associated line graphs are balanced.
Theorem 2.
Let be a -gain graph. Its associated line graphs are balanced if and only if each even directed cycle in Γ is neutral, and the gain of every odd directed cycle in Γ is , i.e., if and only if Φ is switching equivalent to .
Proof of Theorem 2.
By Proposition 1 all directed cycles of a balanced gain graph are neutral. Let be any incidence matrix of . Observe that has three types of cycles:
- (i)
- cycles arising from cycles of ;
- (ii)
- cycles arising from induced stars in (forming cliques); and
- (iii)
- cycles obtained by combining the cycles of Types (i) and (ii).
A directed cycle originating from a directed cycle of has gain . Since every induced star is switching equivalent to , then the induced cliques on are all balanced. Finally, for the cycles of Type (iii), the theory of biased graphs (see [1]) tells that combining positive cycles leads to positive cycles. Hence, the cycles of Type (iii) are positive if and only if so are the cycles of Type (i). The statement now follows easily by Propositions 2 and 6. □
Corollary 1.
If a -gain graph and its associated line graphs are all balanced then Γ is bipartite.
Proof of Corollary 1.
By Theorem 2, if and are both balanced, then does not contain any odd cycle. Hence, the graph is bipartite. □
4. Subdivision Graphs Associated to -Gain Graphs
For any graph , the subdivision graph is obtained from by replacing each of its edges by a path of length 2, or, equivalently, by inserting an additional vertex into each edge e of . Adopting an abuse of notation (which has become classical in this context), we denote by e the additional vertex inserted on the homonymous edge. For the set , we choose the ordering .
Any incident matrix on induces a gain structure on defined in the following way:
for any and for any .
According to the chosen vertex ordering the adjacency matrix of the gain graph is
By Proposition 3, or equivalently by Equation (2), for every edge , we have four different choices for gains of the corresponding pair of ‘new’ edges in the gain subdivision graph. Figure 2, Figure 3 and Figure 4 analyze several possibilities.
It is reasonable to ask what the relation between two different subdivision graphs of the same -gain graph is. The following proposition provides an answer to this question.
Proposition 7.
Let be a -gain graph, and let and be two of its incidence matrices. Then, and are switching equivalent; and are similar and share the same adjacency spectrum.
Proof of Proposition 7.
Proposition 3 guarantees that for a suitably chosen diagonal matrix with diagonal entries in . Taking into account Equation (8), it is not hard to verify that
where the symbol ⊕ denote the block diagonal sum of two matrices.
The switching function such that is defined as follows:
□
Proposition 7 implies that a subdivision graph of a -gain graph is balanced if and only if any other subdivision graph of is balanced.
Proposition 8.
Subdivision graphs of two switching equivalent -gain graphs and are switching equivalent.
Proof of Proposition 8.
We argue as in the proof of Proposition 6. Let be the map such that . If is a fixed incident matrix of , then is an incidence matrix of , where is the state matrix.
Consider the map defined as follows:
It turns out that . In fact,
□
We now investigate which conditions on ensure the balancedness of its subdivision graphs. Figure 5 gives an example of an unbalanced -gain graph having balanced subdivision graphs.
Lemma 2.
Let be a -gain graph, and let be a directed cycle in Γ. Then, for any incident matrix of Φ, we have
Proof of Lemma 2.
The directed cycle is obtained by considering consecutively the following elements in :
Hence,
□
Theorem 3.
Let a -gain graph. Its subdivision graphs are balanced if and only if each even directed cycle of Γ is neutral, and the gain of every odd directed cycle in Γ is , i.e., if and only if Φ is switching equivalent to .
Proof of Theorem 3.
Let and be -gain graphs with the same underlying graph . By Proposition 2, and are switching equivalent if and only if, for every directed cycle in , . Lemma 2 provides a necessary and sufficient condition to obtain all neutral directed cycle in the subdivision graphs coming from : every even directed cycle of should be neutral, and the gain of every odd directed cycle in should be . Clearly satisfies this condition. Since Proposition 8 holds, the proof is completed. □
Corollary 2.
If Γ contains a directed cycle having an imaginary gain, then the -gain graph and its subdivision graphs are all unbalanced.
By Theorems 2 and 3, we may conclude that the structural conditions on to have balanced associated line graphs, or balanced associated subdivision graphs are the same.
Our final result concerns the mutual interrelationships between the Laplacian polynomial of a -gain graph and the adjacency characteristic polynomial of its line graphs and its subdivision graphs. Propositions 5 and 7 allow us to drop the incident matrix out of notations in the statements.
For a -gain graph , let and be the adjacency characteristic polynomial and the Laplacian characteristic polynomial of , respectively.
Theorem 4.
Let Γ be a graph of order n and size m, and Φ a -gain graph having Γ as underlying graph. Then,
- 1.
- ;
- 2.
- .
Proof of Theorem 4.
To prove (1), we use Equations (3) and (6), and the fact that and share the same non-zero eigenvalues.
The argument to prove (2) is essentially the same as the one used in the proof of [10] (Theorem 2.2). We use the Schur’s formula for computing the determinant of a block matrix, namely:
Now,
□
Author Contributions
All authors contributed equally in the preparation of this manuscript.
Funding
This research was funded by Kuwait University, Research Grant No. SM03/18.
Acknowledgments
The authors would like to thank the anonymous referees for their careful reading and their kind appreciation. One of them pointed out that our results possibly encapsulate fruitful applications to the spectral theory of distance matrices. This suggested line of research goes beyond the framework of our paper.
Conflicts of Interest
The authors declare no conflict of interest.
References
- Zaslavsky, T. Biased graphs. I: Bias, balance, and gains. J. Combin. Theory Ser. B 1989, 47, 32–52. [Google Scholar] [CrossRef] [Scilit]
- Zaslavsky, T. A mathematical bibliography of signed and gain graphs and allied areas. Electron. J. Comb. 1998, 5. Available online: https://www.combinatorics.org/ojs/index.php/eljc/article/view/DS8 (accessed on 5 October 2019).
- Reff, N. Spectral properties of complex unit gain graphs. Linear Algebra Appl. 2012, 436, 3165–3176. [Google Scholar] [CrossRef] [Scilit]
- Reff, N. Oriented gain graphs, line graphs and eigenvalues. Linear Algebra Appl. 2016, 506, 316–328. [Google Scholar] [CrossRef] [Scilit]
- Belardo, F.; Brunetti, M.; Reff, N. Balancedness and the least Laplacian eigenvalue of some complex unit gain graphs. Discuss. Math. Graph Theory 2020, in press. [Google Scholar]
- Dong, J.-G.; Lin, L. Laplacian matrices of general complex weighted directed graphs. Linear Algebra Appl. 2016, 510, 1–9. [Google Scholar] [CrossRef] [Scilit]
- Kalita, D. Properties of first eigenvectors and first eigenvalues of nonsingular weighted directed graphs. Electron. J. Linear Algebra 2015, 30, 227–242. [Google Scholar] [CrossRef] [Scilit]
- Bapat, R.B.; Kalita, D.; Pati, S. On weighted directed graphs. Linear Algebra Appl. 2012, 436, 99–111. [Google Scholar] [CrossRef] [Scilit]
- Guo, K.; Mohar, B. Hermitian adjacency matrix of digraphs and mixed graphs. J. Graph Theory 2017, 85, 217–248. [Google Scholar] [CrossRef] [Scilit]
- Belardo, F.; Simić, S.K. On the Laplacian coefficients of signed graphs. Linear Algebra Appl. 2015, 475, 94–113. [Google Scholar] [CrossRef] [Scilit]
- Belardo, F.; Petecki, P. Spectral characterizations of signed lollipop graphs. Linear Algebra Appl. 2015, 480, 144–167. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Gong, S.-C.; Fan, Y.-Z. On the determinant of the Laplacian matrix of a complex unit gain graph. Discrete Math. 2018, 341, 81–86. [Google Scholar] [CrossRef] [Scilit]
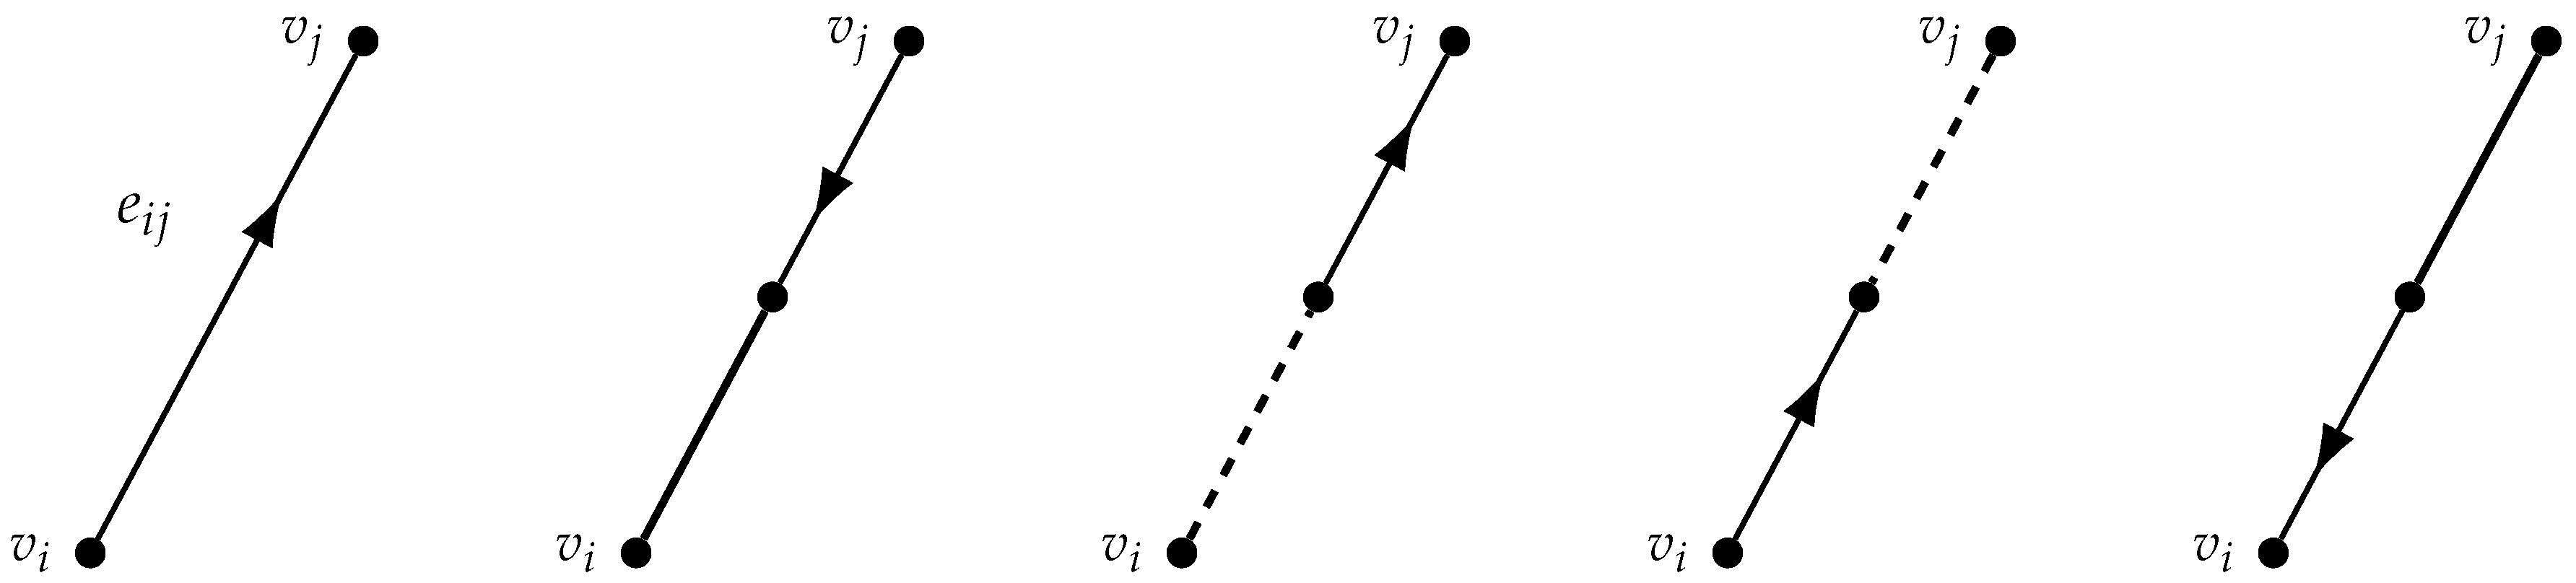
© 2019 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).