


Abstract
This paper introduces a graphical framework for smooth Lie group actions based on tangent orbit interactions. In contrast with classical intersection graphs, where vertices usually represent algebraic subobjects and edges record set-theoretic intersections, the present construction uses non-trivial orbits as vertices and creates edges from common nonzero tangent directions inside the fixed ambient embedding. Starting from infinitesimal tangent spaces generated by the action, we construct Lie orbit tangent graphs and analyze their adjacency structure, connectedness, completeness, degrees and diameter estimates. To describe local and global interactions, tangent fibers, local tangent orbit cliques, tangent orbit hypergraphs and incidence structures are introduced. We further develop separating tangent paths and use them to construct neighborhood systems and tangent-separating topologies. The framework gives a unified way to encode orbit-level tangent interactions and may be useful in geometric analysis, symmetry-based dynamical systems, differential topology and mathematical physics, where orbits and infinitesimal directions describe invariant motions, constraints or symmetry-reduced configurations. Several examples are included to illustrate how Lie group actions, graph structures, hypergraphs and tangent geometry interact within the proposed scheme.
Keywords:
Lie group actions; orbit tangent graphs; tangent fibers; hypergraph structures; incidence structures; separating tangent paths MSC:
22E46; 05C25; 05C65; 57S25; 05C38
1. Introduction
Graph theory provides a mathematical framework for representing interactions among objects through vertices and edges. Owing to its flexibility, graph-theoretical methods have become fundamental tools for modeling complex relationships arising in various disciplines, including computer science, biology, engineering, social sciences, algebra and topology. In recent years, combining graph structures with algebraic and topological frameworks has become an effective approach for investigating structural, combinatorial and interaction-based properties.
Graph theory and algebra are closely related, since many graphs arise naturally from algebraic structures such as groups, rings and semigroups. One important direction in this interaction is the study of intersection graphs, where adjacency is determined by non-trivial intersections between algebraic objects. Chakrabarty et al. [1] extended this idea to ideals of rings. Zelinka [2] introduced intersection graphs for finite Abelian groups, where vertices correspond to subgroups and edges represent non-trivial intersections. Shen [3] studied intersection graphs of subgroups of finite groups. Akbari et al. [4] further investigated structural properties of group intersection graphs. Several studies have focused on graph-theoretical properties of intersection graphs. Zhao et al. [5] investigated connectivity and robustness in random intersection graphs. Kayacan [6] studied connectedness properties of intersection graphs of finite groups. Aprose and Fathima [7] examined intersection power graphs of finite groups. Beheshtipour and Jafarian Amiri [8,9] investigated clique structures and clique numbers associated with intersection graphs.
The concept of intersection graphs has also been extended beyond groups. Ramanathan [10] introduced projective intersection graphs associated with ideals of commutative rings. Moh’d and Ahmed [11] studied simple-intersection graphs of rings, while Ahmed and Moh’d [12] proposed new class of intersection graphs associated with modules.
More recently, intersection graph techniques have been extended to actions and semigroup acts. Rasouli and Tehranian [13] introduced intersection graphs of -acts and investigated their basic properties. Delfan et al. [14] further developed that framework and obtained additional structural results. Khosravi and Roueentan [15] studied algebraic properties of -acts through congruence structures. More recently, Alshammari et al. [16] introduced graphical homotopy constructions for monoid intersection graphs and demonstrated applications involving graphical monoids.
On other hand, graph theory has strong interactions with topology. Several studies have explored how graphs generate topological structures and how topological methods can be interpreted graphically. Tucker [17] investigated graph-theoretic methods in topology through covering-space constructions. Sari and Kopuzlu [18] studied topological spaces generated by simple graphs. Noll [19] investigated graph-theoretic viewpoints related to closed graph structures, while Branman et al. [20] developed graphical models associated with topological groups.
Recent developments have focused on graphical topological structures and their applications. Damag et al. [21] introduced out mondirected topologies and applied them to human nervous systems. Alzubaidi et al. [22] studied topologies generated from graphs and their applications. Damag et al. [23] proposed upper -graphical topological spaces together with applications. More recently, Damag et al. [24] introduced monophonic sets and rough directed topological spaces and demonstrated their applicability to directed networks. Some contributions also show the usefulness of hypergraph and path-based graph methods in modern mathematical modelling. For example, Zhao et al. [25] investigated vulnerability measures for uniform hypergraph networks through scattering numbers, while Kalampakas [26] developed path-based hyperoperations on fuzzy graphs. These studies support the broader view that graph and hypergraph constructions can encode higher-order relations that are not visible in ordinary pairwise models.
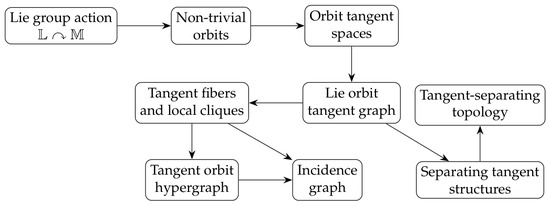
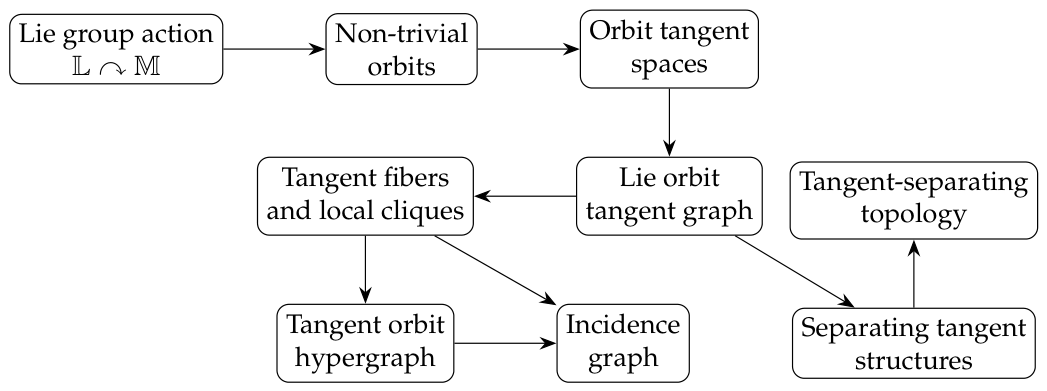
The graph introduced in this work (Figure 1) differs from the above intersection-graph constructions in two essential ways. First, its vertices are not subgroups, ideals, modules or semigroup acts but non-trivial orbits of a smooth Lie group action. Second, adjacency is not determined by a direct set-theoretic intersection of the vertices themselves; it is determined by the existence of a common nonzero tangent direction between tangent spaces of two orbits after these tangent spaces are realized in the ambient Euclidean space. Thus, the proposed graph is an extrinsic tangent-interaction graph associated with infinitesimal orbit geometry, rather than a classical intersection graph of algebraic objects.
Figure 1.
Schematic relationship among the main objects used in the paper. The Lie group action produces orbit tangent spaces; common tangent directions generate the Lie orbit tangent graph, tangent fibers and local cliques. These fibers produce hypergraph and incidence structures, while separating tangent directions generate tangent neighborhoods and the associated tangent separating topology.
This distinction also provides practical motivation. In geometry and differential topology, the construction can be used as a combinatorial summary of how orbit tangent spaces overlap across different orbit families. In dynamical systems and symmetry analysis, it identifies pairs or clusters of symmetry-generated motions that share infinitesimal directions. In mathematical physics, such tangent interactions may describe common infinitesimal modes in configuration spaces with symmetries, constrained systems or symmetry-reduced phase spaces. The associated hypergraph and incidence structures then record higher-order common tangent directions among several orbits, while separating tangent directions detect edges generated by directions unique to a given pair of orbit vertices.
The interaction between graph theory, Lie group actions and geometric structures has attracted considerable attention due to its ability to reveal hidden relations between algebraic, topological and dynamical systems. Although intersection graphs and graphical topologies associated with algebraic structures have been extensively studied, little attention has been devoted to constructing graph structures directly from tangent orbit interactions generated by Lie group actions. Moreover, relationships between tangent fibers, hypergraph structures, incidence methods and orbit connectivity remain largely unexplored. Motivated by these observations, this work develops new framework that combines graph-theoretical, geometric and hypergraph techniques for studying orbit interactions through tangent structures.
The main contributions of this work can be summarized as follows. We introduce Lie orbit tangent graphs generated from infinitesimal tangent interactions associated with smooth Lie group actions and investigate their fundamental structural properties. We define tangent fibers and local tangent orbit cliques, and we establish how they decompose the edge structure and control connectivity and domination. We construct tangent orbit hypergraphs and incidence graphs to record higher-order common tangent directions and to characterize global orbit interactions. We introduce separating tangent paths and tangent-separating neighborhood systems, leading to a topology generated by tangent interaction data. Finally, we prove connectedness results linking tangent-separating paths, hypergraph fiber chains, incidence relations and connectedness properties of the induced topological space.
Section 2 introduces Lie orbit tangent graphs together with their basic constructions, examples, and structural properties. Section 3 studies tangent orbit fibers, local tangent orbit cliques, and their effects on connectivity and domination. Section 4 develops hypergraph and incidence structures associated with and investigates their graph-theoretical properties. Section 5 introduces tangent-separating structures and develops the tangent-separating topology together with its connectedness properties.
Throughout this work, a graph is written in the form , where and represent the collections of vertices and edges, respectively. The cardinality of is called the order of and is denoted by . For a vertex , the quantity denotes the number of neighboring vertices of q. A path in refers to an ordered sequence of distinct vertices such that every two successive vertices are adjacent. The graph is said to be connected whenever arbitrary vertices can be linked through a path. For vertices p and q, the distance is defined as the smallest length among all possible paths connecting them; if no connecting path exists, we set . The diameter of is given by
A clique in is a subgraph in which every two distinct vertices are adjacent. A path component of refers to a connected subgraph that is maximal under set inclusion. Let be nonempty. The set A is called dominating whenever each vertex belonging to is adjacent to at least one element of A.
A hypergraph is represented by the pair , where denotes the vertex collection, and is a family of subsets called hyperedges. The associated two-section graph of is constructed by connecting distinct vertices whenever they appear together in at least one hyperedge.
The fundamental concepts and results from topology that are required throughout this work can be found in standard references; see [27]. Recall [28] that a chart on a topological space consists of a pair , where is an open subset, and maps U homeomorphically onto a subset of . A smooth manifold of dimension n is a Hausdorff and second-countable topological space equipped with an atlas satisfying the compatibility condition that whenever , the coordinate change maps
are smooth mappings. Recall [28] that a Lie group is a smooth manifold equipped with a group operation such that both multiplication and inversion are smooth mappings. More precisely, the multiplication map given by and the inversion map defined by are smooth.
2. Lie Orbit Tangent Graphs
This section introduces the construction of Lie orbit tangent graphs associated with smooth Lie group actions. The necessary geometric preliminaries are first presented, followed by proposed graph construction and illustrative examples. Several structural properties including connectedness, completeness, degree characterization and diameter estimates are then established.
A smooth action of a Lie group on a smooth manifold is a smooth map defined by such that and for all and .
For , the orbit generated by m is given by Let be a smooth manifold and fix . The tangent space associated with m, denoted by , is defined by
Let denote the identity element. The Lie algebra corresponding to , denoted by , is defined by Assume that is a Lie group with Lie algebra . The exponential mapping is written as For each , the curve generates a one-parameter subgroup. For each , define the associated fundamental vector field by
Given , denote by the tangent space of the orbit at the point m. The orbit tangent space admits the following representation:
An orbit is called non-trivial if for every Since is an embedded manifold, every tangent space is canonically identified with a linear subspace of Therefore, tangent spaces associated with different points are compared through their ambient realization inside
Definition 1.
Let act smoothly on an embedded manifold We define the Lie orbit tangent graph as the graph whose vertex set consists of all non-trivial orbits arising from the action. Two distinct orbit vertices and are connected by an edge whenever there are points and satisfying
where the corresponding tangent spaces are viewed as linear subspaces of
The construction is also meaningful when the action has infinitely many non-trivial orbits. In that case, is understood as a possibly infinite simple graph whose vertices are all non-trivial orbits and whose edges are determined by the same tangent-intersection condition. Results based only on finite paths, such as the existence of connecting paths or fiber chains, continue to have the same interpretation. Results involving degrees, domination numbers, diameters or incidence counts require the corresponding local finiteness or finite-incidence assumptions, or else they must be read in terms of cardinal invariants. Throughout the remainder of this paper, unless otherwise stated, we work under the standing assumption that has finitely many vertices and that the associated tangent orbit hypergraphs and incidence graphs have finitely many incidences.
It is important to emphasize that the present definition is extrinsic: the embedding is part of the data. Tangent spaces at different points are compared after being realized as linear subspaces of the same ambient Euclidean space. Therefore, two different embeddings may in principle produce different adjacency relations unless they preserve the relevant tangent intersections, for example under an ambient linear isometry or under an embedding equivalence that carries common tangent directions to common tangent directions. An intrinsic variant would require an additional comparison device, such as a connection, parallel transport or a chosen trivialization; this lies beyond the present paper.
Example 1.
Consider the Lie group acting smoothly on the embedded manifold by horizontal translations, that is, for all and . For each , the orbit of m is Thus, the non-trivial orbits are the horizontal lines , where and . The Lie algebra of is . For , the fundamental vector field is given by
Hence, for every , we have Therefore, for any two distinct orbits and with , choose points and Since
we obtain
Consequently, every two distinct vertices are adjacent and hence the Lie orbit tangent graph is a complete graph.
Example 2.
Let be a Lie group and let be the standard basis of . Define the following three-dimensional subspaces:
For each , define and Let
Define a smooth action of on as follows. If and define where is the linear isomorphism mapping the standard basis vectors of onto the generators of . Hence, each is one orbit, that is, for every Since for every we obtain
Therefore, for every point we have In particular, for every and Hence,
Moreover, let and Since and we obtain
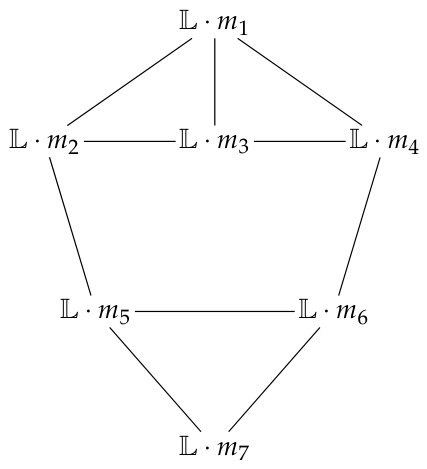
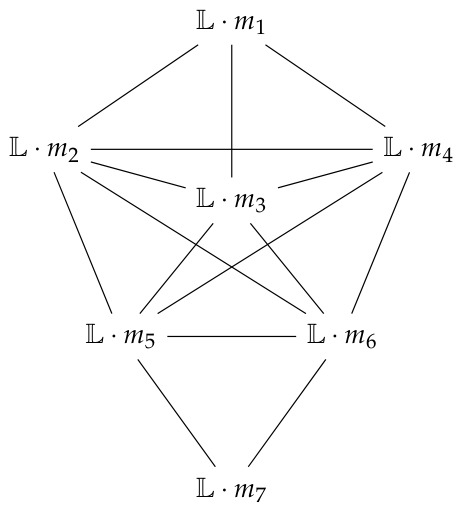
All remaining pairwise intersections are equal to , and hence adjacency follows; see the Lie orbit tangent graph in Figure 2.
Figure 2.
The Lie orbit tangent graph in Example 2.
Theorem 1.
Let act smoothly on an embedded manifold . For each , define the infinitesimal action map by . If, for any two distinct non-trivial orbits and , and for all points and , we have then is edgeless.
Proof.
Let and be two distinct non-trivial orbits. Let and For each , the smooth curve lies in the orbit . Hence, its velocity vector at is
Thus, . Conversely, every tangent vector to the orbit at x is generated by some one-parameter subgroup of and therefore, Similarly, By the hypothesis, Hence,
Since this holds for all and there are no points in the two orbits whose tangent spaces have a nonzero intersection. Therefore, and are not adjacent. Since this holds for every two distinct non-trivial orbits, is edgeless. □
Theorem 2.
Let act smoothly on an embedded manifold and let
For each , define the infinitesimal action map by . Then,
In particular, if for every , there exist and such that then is complete, and for every .
Proof.
Fix . Let . For each , the smooth curve lies in the orbit . Hence,
Thus, Similarly, Therefore, the adjacency condition is equivalent to
for some and Hence,
If for every there exist such points x and y, then every two distinct vertices are adjacent. Hence, is complete, and each vertex is adjacent to the remaining vertices. Thus, for every . □
Theorem 3.
Let act smoothly on an embedded manifold and let
Suppose that there is a non-trivial orbit such that, for every , there exist points and together with satisfying Then, is connected, and .
Proof.
For each , choose points and together with such that Define the two smooth curves and Since lies in the orbit , its velocity vector at belongs to . Hence,
Similarly, since lies in the orbit , we have
By hypothesis, Therefore,
Thus, every vertex is adjacent to the vertex . Now, let and be any two distinct vertices. If they are adjacent, then their distance is one. If they are not adjacent, then both are adjacent to and hence, is a path of length two. Hence, every two vertices are connected by a path of length at most two. Consequently, is connected, and . □
Theorem 4.
Let act smoothly on an embedded manifold and let
Suppose that there exist nonzero vectors such that
and for every , we have . Then, is connected.
Proof.
For each , we first show that induces a complete subgraph. Let and be two distinct vertices in . Then, there exist points and such that and Since , we have
Hence, the two vertices are adjacent. Thus, is a clique. Now, let and be any two vertices. By the covering assumption, there exist such that and . If , then both vertices lie in the same clique , so they are adjacent or equal. Assume that . Since for every , choose a vertex . Since is a clique, is connected to . Since and , the vertices and are adjacent or equal for each . Finally, since and , they are adjacent or equal. Thus, there is a path from to . If , the same argument applies after interchanging p and s. Therefore, every two vertices are connected by a path. Hence, is connected. □
Theorem 5.
Let act smoothly on an embedded manifold . Suppose that there is a nonzero vector such that for every non-trivial orbit , there exist a point and an element satisfying Then, is complete.
Proof.
Let and be two distinct non-trivial orbits. By hypothesis, there exist points and together with such that and Define the smooth curves and Since lies in the orbit , its velocity vector at belongs to . Hence,
Similarly,
Thus, Since , we obtain
Therefore, and are adjacent. Since this holds for every two distinct non-trivial orbits, is complete. □
3. Global Properties of Lie Orbit Tangent Graphs
This section investigates the local tangent structure of through tangent orbit fibers and local tangent orbit cliques. We study how common tangent directions generate adjacency relations and determine global graph properties. In particular, we establish decomposition results, derive connectivity and domination properties and present applications illustrating how local tangent interactions control the overall graph structure. For each nonzero vector , define
The set is called the tangent orbit fiber determined by v. The number is called the tangent orbit multiplicity of v. If , then v is called a common tangent direction. For , the subgraph induced by is called the local tangent orbit clique at v and is denoted by .
For example, in Example 2, the common direction gives the tangent fiber ; hence, the local tangent orbit clique consists of the edge joining these two vertices. Similarly, gives . Thus, a tangent fiber records all orbit vertices that share a specified infinitesimal direction, while the associated local clique records the pairwise adjacencies forced by that direction.
Theorem 6.
The Lie orbit tangent graph is the edge union of its local tangent orbit cliques , where v runs over all nonzero vectors of .
Proof.
We prove that every edge of appears in some local tangent orbit clique and conversely every edge appearing in a local tangent orbit clique is an edge of . Let and be two distinct vertices of . Suppose first that they are adjacent. Then, there exist points and such that
Hence, there is a nonzero vector such that and Therefore, and so the edge belongs to the local tangent orbit clique . To see the infinitesimal origin of this common direction, use the characterization and Thus, there exist such that Equivalently, for the curves and we have
Hence, the edge is generated by a common nonzero infinitesimal direction. Conversely, suppose that and are adjacent inside some local tangent orbit clique . Then, By the definition of , there exist points and such that and Since , it follows that
Therefore, and are adjacent in . Hence, the edge set of is exactly the union of the edge sets of all local tangent orbit cliques . That is,
is an edge union. □
Theorem 7.
Let act smoothly on an embedded manifold . Let Θ be a clique in . If there exist points for each vertex such that
then there is a nonzero vector such that . Consequently, Θ is contained in the local tangent orbit clique . In particular, if every clique of has a nonzero common tangent direction, then
Proof.
Let be a clique and assume that there exist points such that
Then, there is a nonzero vector satisfying for every . By definition of , this implies for all j. Hence, Therefore, is contained in Now, we show compatibility with Theorem 6. By Theorem 6, every edge of is generated by at least one nonzero common tangent direction. In the present case, the same vector v belongs to all tangent spaces associated with the vertices of . Hence, every edge inside is generated by the same local tangent fiber . Therefore, is contained in one local tangent orbit clique. It remains to prove the equality for the clique number. For every nonzero vector , the subgraph is complete. Indeed, if with distinct vertices, then there exist points such that and Hence,
Therefore, the vertices are adjacent, and is a clique of order . Consequently,
Conversely, let be a clique of maximum cardinality. By assumption, possesses a nonzero common tangent direction. Hence, there is such that Therefore,
Since we obtain
Combining both inequalities gives □
Theorem 8.
Let be the family of all local tangent orbit cliques. Suppose that for every two cliques , there is a finite sequence such that for all . Then, is connected.
Proof.
Let and be arbitrary vertices of . Choose local tangent orbit cliques and such that If , then is complete. Hence, and are connected. Assume now that . By hypothesis, there is a sequence
Since choose a vertex for every . Since and is complete, is adjacent to . Similarly, since and is complete, is adjacent to for every . Finally, since and is complete, is adjacent to . Therefore,
is a path joining and . Hence, is connected. □
Theorem 9.
Let be a family of local tangent orbit cliques such that Choose one vertex for each Then, is a dominating set of Consequently,
Proof.
Let be an arbitrary vertex of . If , there is nothing to prove. Assume that . Since
there is such that Since both vertices and belong to the same local tangent orbit clique. Since is complete, is adjacent to . Hence, every vertex outside D is adjacent to some vertex of D. Therefore, D is a dominating set of . Consequently, □
Let act smoothly on an embedded manifold . Define the tangent fiber incidence graph as the bipartite graph whose first part is and whose second part is A vertex is adjacent to a vector v if and only if there is a point such that In this bipartite graph, one side consists of orbit vertices, and the other side consists of common tangent directions. For instance, in Example 2, the direction is joined to the orbit vertices and , while the direction is joined to and . Thus, incidence edges explicitly record which orbit vertices participate in each common tangent direction.
Theorem 10.
Let act smoothly on an embedded manifold . A vertex is adjacent to a vector v in whenever there is such that . Then, two non-trivial orbits and belong to the same connected component of if and only if they belong to the same connected component of . Moreover, whenever the distance in is finite,
Proof.
Let and be two non-trivial orbits. Assume first that they belong to the same connected component of . Then, there is a path
For each , the vertices and are adjacent. Hence, there exist points and such that
Choose a nonzero vector Then, , so is a vertex of . Since and , the incidence path
is in . Hence, the two orbit vertices belong to the same connected component. Conversely, assume that and belong to the same connected component of . Since is bipartite, there is a path
For every i, there exist points and such that and Therefore,
Then, the vertices and are adjacent. Hence,
is a path in . Finally, suppose Since is bipartite, every shortest path has even length, say, Then, the previous argument yields a path in of length r. Hence,
The proof is complete. □
Proposition 1.
Let be the three-dimensional Abelian Lie group
Let be the standard basis of and define
For , let , define , put and let be the linear isomorphism sending the standard basis of onto the generators of . Define the action by
where
Then, has seven vertices and ten edges, contains a triangle, is connected and is neither complete nor cyclic.
Proof.
The Lie algebra of is
Let
Since , we have . Let and define . Then, Therefore,
Hence, Since is onto , we obtain
Because each is surjective, the action is transitive on every component . Therefore, and
Now,
and All remaining pairwise intersections equal . Since the tangent space along each orbit is constant and equal to , Definition 1 implies that
Hence, the graph has seven vertices and ten edges. Moreover, form a triangle since every pair shares the direction . The graph is connected because every vertex outside this triangle is adjacent to one of its vertices. The graph is not complete since . Hence, for every and , we have and therefore, and are not adjacent. Also, the graph is not cyclic because it contains a triangle and vertices of degree greater than two. Therefore, the proposition follows. □
4. Hypergraph and Incidence Structures of
This section investigates the global structure of through tangent fiber incidence methods and hypergraph techniques.
Definition 2.
Let act smoothly on an embedded manifold . The tangent orbit hypergraph associated with is denoted by and defined by where and Each hyperedge consists of all orbit vertices for which there is a point on the orbit whose tangent space contains the common nonzero direction v.
To illustrate this definition, Example 2 gives hyperedges such as , and . Each hyperedge groups all orbits sharing one common tangent direction. In examples where a direction is shared by more than two orbits, the corresponding hyperedge has cardinality greater than two and records a genuinely higher-order tangent interaction rather than only a pairwise edge.
Theorem 11.
The graph is exactly the 2-section graph of the tangent orbit hypergraph .
Proof.
Let and be two distinct vertices of . Suppose first that they are adjacent in . Then, there exist points and such that
Hence, there is a nonzero vector such that and Therefore, and since , the set is a hyperedge of . Thus, the two vertices are contained in a common hyperedge, so they are adjacent in the 2-section graph of . Conversely, suppose that and are adjacent in the 2-section graph of . Then, there is a hyperedge such that By the definition of , there exist points and such that and Since , we obtain
Hence, and are adjacent in . Therefore, both graphs have the same vertex set and the same edge set, so is exactly the 2-section graph of . □
Theorem 12.
Let . Then, S is an independent set of if and only if for every two distinct vertices , every points , , and every , we have whenever and . Equivalently, S is independent if and only if for every hyperedge .
Proof.
Assume first that S is an independent set of . Let and be two distinct vertices in S. Suppose, to the contrary, that there exist points , , and elements such that . Define the smooth curves and . Since lies in and lies in , we have
and
Put . Since , we obtain Therefore,
Hence, the two vertices are adjacent in , contradicting independence. Thus, no two distinct vertices of S can share the same nonzero fundamental tangent direction. Conversely, assume that for every two distinct vertices , every points , , and every , the equality never occurs. Suppose that S is not independent. Then, there exist two adjacent vertices . Then, there exist points and such that
Hence, there is . By the tangent characterization of orbits, there exist satisfying and . Therefore, , contradicting the hypothesis. Hence, S is independent. It remains to prove the hypergraph formulation. By Theorem 11, is the 2-section graph of . Hence, two vertices are adjacent if and only if they belong to a common hyperedge . If S is independent and for some hyperedge, then two vertices of S belong to the same hyperedge and are therefore adjacent, a contradiction. Thus, for every . Conversely, assume for every hyperedge. If two vertices of S were adjacent, then Theorem 6 would provide a nonzero tangent direction v generating this edge, so both vertices would belong to , contradicting . Therefore, S is independent. □
Theorem 13.
Let . Then, is a dominating set of if and only if for every vertex , there is a nonzero vector such that and . Equivalently, every vertex outside shares a nonzero infinitesimal tangent direction with at least one vertex of .
Proof.
Assume first that is a dominating set of . Let . Since is dominating, there is a vertex such that is adjacent to . Then, there exist points and satisfying
Hence, there is a nonzero vector Therefore, and Thus, Conversely, suppose that for every vertex , there is such that and Choose Since both vertices belong to , there exist points and such that and Since , we obtain
Hence, is adjacent to . Therefore, every vertex outside is adjacent to a vertex of , so is dominating. To express this infinitesimally, let and choose as above. Since and the tangent characterization gives elements satisfying Equivalently, for the curves and we have
Therefore, every vertex outside is controlled by a vertex of through a common nonzero infinitesimal tangent direction. □
Theorem 14.
Let be a family of tangent directions such that covers . If for each , there is a vertex , then the set is a dominating set of . In particular, if denotes the minimum number of tangent fibers needed to cover , then
Proof.
Let be any vertex of . Since covers , there is such that By construction, If then Assume now that Since both vertices belong to , there exist points and such that and Since , we obtain Hence, is adjacent to . Therefore, every vertex is either contained in or adjacent to a vertex of . Thus, is a dominating set. Now, let be the minimum cardinality of a family of tangent fibers covering . Choose a covering family with By the first part, choosing one vertex from each fiber gives a dominating set satisfying Since is the minimum cardinality of a dominating set, we obtain □
Theorem 15.
Let act smoothly on an embedded manifold , and let be the tangent orbit hypergraph. Suppose that there exists an integer such that for every two vertices , there is a sequence of hyperedges , where , satisfying and for every Then, is connected and
Proof.
Let . By hypothesis, there is a sequence of hyperedges , where , such that , , and for every . Choose vertices for . Since , Theorem 11 implies that either , or they are adjacent in . Similarly, for every , the vertices and belong to the same hyperedge , so they are equal or adjacent by Theorem 11. Finally, since , they are equal or adjacent. Consequently,
gives a path after removing repeated consecutive vertices. Hence, Since the choice of vertices was arbitrary, every two vertices are connected. Therefore, is connected, and □
Theorem 16.
Under the standing finiteness assumptions, let denote the number of incidences in the tangent fiber incidence graph . Then,
where denotes the tangent-direction part of .
Proof.
The tangent fiber incidence graph is bipartite with parts and . An incidence in is an edge joining an orbit vertex to a tangent direction v whenever there is such that . For a fixed tangent direction , the number of orbit vertices incident with v is exactly . Summing over all tangent directions in gives
On the other hand, counting the same incidences from the orbit-vertex side, the number of tangent directions incident with a fixed vertex is precisely its degree in the incidence graph. Hence,
Since both sums count the same incidence edges of , once by tangent directions and once by orbit vertices, we obtain the desired result. □
Proposition 2.
Let be the Lie group
Let be the standard basis of and define
For , let , define , put and define the action by
where is the natural linear isomorphism. Then, has six vertices and seven edges, contains five hyperedges, and .
Proof.
The Lie algebra is
Let
Since , we have . Let . Define . Then, Therefore,
Hence, and therefore,
Since every is surjective, each component is one orbit. Therefore,
Now
and All remaining intersections are equal to . Since the tangent spaces are constant along every orbit and equal to , Definition 1 implies that
Therefore, the graph has seven edges. Moreover,
and Thus, has five hyperedges. Observe that
is a path joining and which has length three. Also,
shows that some vertex pairs have distance at least three. Since every pair of vertices can be connected by a path containing at most three edges, we obtain Finally, dominates every vertex. Since no single vertex dominates together with we obtain □
5. Tangent-Separating Structures and Tangent Topologies
This section introduces tangent-separating structures in and investigates how separating tangent directions determine local and global properties of the graph. We define tangent-separating paths and construct tangent topologies generated by their neighborhood systems. These structures provide a refined description of connectivity and tangent interactions between orbit vertices.
Definition 3.
Let and be adjacent vertices of . A nonzero vector v is called a separating tangent direction if there exist points and such that and for every vertex and every point , we have
Definition 4.
Let and be two vertices of . A path
is called a tangent-separating path (short, ts-path) if for every , there is a separating tangent direction together with points and such that
Definition 5.
The tangent-separating neighborhood of a vertex , denoted by , is defined as the set consisting of together with all vertices such that there is a ts-path of length at most two connecting and .
For example, in Example 3, the vector is a separating tangent direction for the edge joining and , because it belongs to and does not belong to any other orbit tangent space in that construction. Hence, this edge itself is a ts-path of length one. The neighborhood then collects vertices that can be reached from by at most two such separating steps.
Define
A subset is called -open whenever for every we have The resulting topology on is called the tangent-separating topology and is denoted by
Example 3.
Let be the five-dimensional Abelian Lie group
Let
be a basis of , where each symbol denotes the basis vector indexed by the pair . Define
For , let define and put Let be the linear isomorphism sending the standard basis of onto the five displayed generators of . For written as
and for define
Since for all the affine sets are pairwise disjoint. Also, since each is onto , each is a non-trivial orbit, say, The Lie algebra consists of matrices
Since we have Hence, for
Thus, for every and every The nonzero intersections are exactly
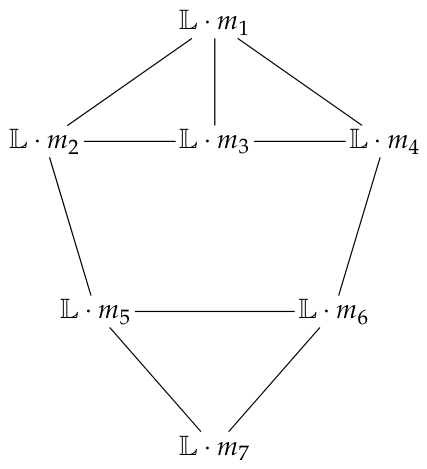
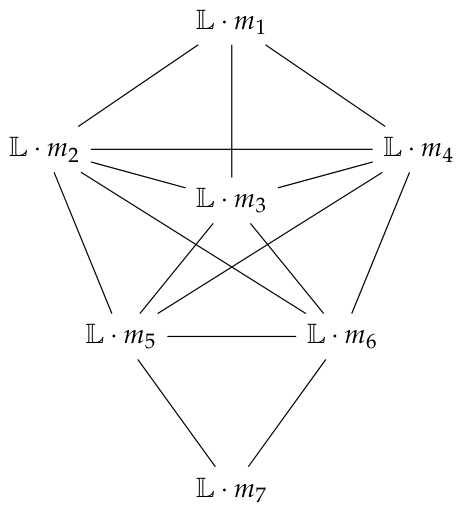
All remaining pairwise intersections are equal to . Since tangent spaces are constant along each orbit and equal to the corresponding subspaces , Definition 1 implies that has seven vertices and exactly fifteen edges. Moreover, every displayed edge has a separating tangent direction, because each vector belongs only to the two corresponding orbit tangent spaces associated with and ; see Figure 3. Since there is no ts-path of length at most two joining and , while every other vertex is joined to by a ts-path of length at most two, we get Similarly,
For every vertex is connected to by a ts-path of length at most two. Hence,
Therefore,
where
Figure 3.
corresponding to Example 3.
Theorem 17.
Suppose that is connected and every edge of admits a separating tangent direction. Then, every two vertices of are connected by a ts-path.
Proof.
Let and be arbitrary vertices of . Since is connected, there is a path
For each , the pair and is an edge of . By hypothesis, this edge admits a separating tangent direction. Hence, there is a nonzero vector together with points and such that and for every vertex and every point Therefore, every edge of the path admits a separating tangent direction. Hence,
is a ts-path. Since and were arbitrary, every two vertices are connected by a ts-path. □
Theorem 18.
If every two vertices of are connected by a ts-path, then the topological space is connected.
Proof.
Suppose that is disconnected. Then, there exist nonempty disjoint open sets U and V such that Choose and Since every two vertices are connected by a ts-path, there is a ts-path
Since and there exists an index k such that and Since U is open and the definition of implies that Because is part of a ts-path, we have Hence, which contradicts the choice of Therefore,
is connected. □
Theorem 19.
Let be the graph whose vertex set is and whose edges are exactly the edges of admitting separating tangent directions. Then, the connected components of coincide with the ts-path components of . In particular, if is connected, then is connected.
Proof.
For a vertex , let denote the set of all vertices connected to O by a ts-path in . We first prove that is open. Let . If , then P and Q are connected by a ts-path of length at most two. Since O is connected to P by a ts-path, concatenating the two paths gives a ts-path from O to Q. Hence, and therefore, By the definition of , this implies that is open. Now, we show that is closed. The complement is a union of ts-path components different from . By the first part, each such component is open. Hence, the complement of is open and therefore is closed. Assume that where U and V are nonempty disjoint subsets open in the subspace topology on Choose and Since there exists a ts-path
Since and there exists an index k such that and Since U is open in the subspace topology and we obtain Because is part of a ts-path, Since also we obtain contradicting the choice of Therefore, is connected. Thus, every ts-path component is connected, open, and closed. Since different ts-path components are disjoint and cover they are exactly the connected components of In particular, if is connected, then there is only one ts-path component. Hence, the whole space is connected. □
Theorem 20.
Let be the tangent orbit hypergraph and let be the graph whose edges are exactly the edges of admitting separating tangent directions. Suppose that for every two vertices of , there is a finite sequence of tangent fibers such that the first vertex belongs to , the second vertex belongs to , for every and every edge in the 2-section graph induced by these fibers admits a separating tangent direction. Then, the topological space is connected.
Proof.
Let and be arbitrary vertices of . By hypothesis, there is a finite sequence of tangent fibers
such that and for every Choose for By Theorem 11, is the 2-section graph of . Hence, any two distinct vertices contained in the same tangent fiber are adjacent. Therefore, after removing repeated consecutive vertices if necessary, we obtain
By hypothesis, every edge in this path admits a separating tangent direction. Therefore, the obtained path is a ts-path. Since the vertices were arbitrary, every two vertices are connected by a ts-path. Hence, by Theorem 18, is connected. □
Theorem 21.
Let be an edge of admitting a separating tangent direction v. Then, there exist points and and an element such that Moreover, .
Proof.
Since is an edge admitting a separating tangent direction, there exist points and such that
Since , by the characterization of orbit tangent spaces, there is such that
Because v is separating, the edge itself forms a ts-path of length one. Therefore, □
Corollary 1.
Suppose that every edge of admits a separating tangent direction. Then, the following are equivalent:
- 1.
- is connected.
- 2.
- Every two vertices are connected by a ts-path.
- 3.
- The tangent orbit hypergraph is fiber-connected.
- 4.
- is connected.
Proof.
Assume that is connected. Since every edge admits a separating tangent direction, Theorem 17 implies that every two vertices are connected by a ts-path. Hence, holds. Assume that every two vertices are connected by a ts-path. Let and be arbitrary vertices. Then, there is a ts-path
For each edge there is a separating tangent direction and points and such that Therefore, Hence, the sequence
forms a chain of tangent fibers joining the two vertices. Thus, the tangent orbit hypergraph is fiber-connected. Suppose that the tangent orbit hypergraph is fiber-connected. Then, Theorem 20 implies that every two vertices are connected by a ts-path. Therefore, by Theorem 18, is connected. Suppose that is connected. Assume that is disconnected. Then, the vertex set can be written as a disjoint union where there are no graph edges joining a vertex of A to a vertex of B. Consequently, no ts-path joins a vertex of A to a vertex of B. By Theorem 19, ts-path components coincide with connected components of the topological space. Hence, A and B determine two disjoint nonempty clopen subsets of contradicting connectedness. Therefore, is connected. □
6. Conclusions
In this work, we introduced Lie orbit tangent graphs as an extrinsic graph-theoretical framework associated with smooth Lie group actions. The main novelty is that orbit vertices are connected through common nonzero ambient tangent directions, rather than through ordinary set-theoretic intersections of algebraic subobjects. This makes the construction sensitive to infinitesimal orbit geometry and separates it from classical intersection graphs. We developed tangent fibers, local tangent orbit cliques, tangent orbit hypergraphs and incidence graphs in order to describe pairwise and higher-order tangent interactions among orbit vertices. We also introduced separating tangent directions, tangent-separating paths and tangent-separating neighborhood systems and used them to construct a topology generated by tangent-interaction data. The obtained results establish connectedness criteria, clique and domination descriptions, incidence-count identities, diameter estimates and relationships between fiber-connected hypergraphs and connected tangent separating topologies.
The framework may be useful in geometric analysis, differential topology, dynamical systems, symmetry analysis and mathematical physics. In these settings, Lie group orbits often represent symmetry classes, invariant motions or reduced configurations, while tangent directions represent infinitesimal transformations. The proposed graph and hypergraph structures provide a combinatorial language for detecting shared infinitesimal modes and higher-order orbit interactions. The present study is intentionally foundational. The construction depends on the chosen ambient embedding used to compare tangent spaces, and most global counting statements were formulated under finite-vertex or finite-incidence assumptions. Future work may develop intrinsic versions using connections or parallel transport, study locally finite infinite orbit graphs, investigate weighted or directed versions based on the dimension or orientation of tangent intersections, and apply the framework to concrete symmetry-reduced models in geometry and mathematical physics.
Author Contributions
Conceptualization, M.F.A. and K.A.; methodology, M.F.A., A.A., F.A. and K.A.; formal analysis, M.F.A., A.A., F.A. and K.A.; investigation, M.F.A., A.A., F.A. and K.A.; writing—original draft preparation, M.F.A., A.A. and F.A.; writing—review and editing, K.A.; supervision, K.A. All authors have read and agreed to the published version of the manuscript.
Funding
This research has been funded by the Deanship of Scientific Research at University of Ha’il—Saudi Arabia through project number BA-26 003.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Chakrabarty, I.; Ghosh, S.; Mukherjee, T.K.; Sen, M.K. Intersection graphs of ideals of rings. Discret. Math. 2009, 309, 5381–5392. [Google Scholar] [CrossRef] [Scilit]
- Zelinka, B. Intersection graphs of finite abelian groups. Czechoslov. Math. J. 1975, 25, 171–174. [Google Scholar] [CrossRef] [Scilit]
- Shen, R. Intersection graphs of subgroups of finite groups. Czechoslov. Math. J. 2010, 60, 945–950. [Google Scholar] [CrossRef] [Scilit]
- Akbari, S.; Heydari, F.; Maghasedi, M. The intersection graph of a group. J. Algebra Its Appl. 2015, 14, 1550065. [Google Scholar] [CrossRef] [Scilit]
- Zhao, J.; Yagan, O.; Gligor, V. On connectivity and robustness in random intersection graphs. IEEE Trans. Autom. Control 2016, 62, 2121–2136. [Google Scholar] [CrossRef] [Scilit]
- Kayacan, S. Connectivity of intersection graphs of finite groups. Commun. Algebra 2018, 46, 1492–1505. [Google Scholar] [CrossRef] [Scilit]
- Aprose, M.A.; Fathima, S.S.A. Further results on intersection power graph of finite groups. Punjab Univ. J. Math. 2020, 52, 47–53. [Google Scholar]
- Beheshtipour, A.; Jafarian Amiri, S.M. The clique number of the intersection graph of a finite group. Bull. Iran. Math. Soc. 2023, 49, 74. [Google Scholar] [CrossRef] [Scilit]
- Beheshtipour, A.; Jafarian Amiri, S.M. The clique number of the intersection graph of some cyclic groups. Int. J. Group Theory 2025, 15, 9–16. [Google Scholar] [CrossRef]
- Ramanathan, V. On projective intersection graph of ideals of commutative rings. J. Algebra Its Appl. 2021, 20, 2150017. [Google Scholar] [CrossRef] [Scilit]
- Moh’d, F.; Ahmed, M. Simple-intersection graphs of rings. AIMS Math. 2023, 8, 1040–1054. [Google Scholar] [CrossRef] [Scilit]
- Ahmed, M.; Moh’d, F. A new intersection-graph type for modules. Commun. Algebra 2024, 52, 2065–2078. [Google Scholar] [CrossRef] [Scilit]
- Rasouli, H.; Tehranian, A. Intersection graphs of S-acts. Bull. Malays. Math. Sci. Soc. 2015, 38, 1575–1587. [Google Scholar] [CrossRef] [Scilit]
- Delfan, A.; Rasouli, H.; Tehranian, A. Intersection graphs associated with semigroup acts. Bull. Iran. Math. Soc. 2019, 45, 131–148. [Google Scholar] [CrossRef] [Scilit]
- Khosravi, R.; Roueentan, M. Chain conditions on (Rees) congruences of S-acts. J. Algebra Its Appl. 2024, 23, 2450085. [Google Scholar] [CrossRef] [Scilit]
- Alshammari, M.F.; Alshuhail, A.; Saif, A. Intersection graphs of monoids in a graphical homotopy framework via path spaces and homogeneous structures: Some applications to graphical comprehensive monoids. Mathematics 2026, 14, 1345. [Google Scholar] [CrossRef] [Scilit]
- Tucker, T.W. Some topological graph theory for topologists: A sampler of covering space constructions. In Topology and Combinatorial Group Theory; Latiolais, P., Ed.; Lecture Notes in Mathematics; Springer: Berlin/Heidelberg, Germany, 1990; Volume 1440. [Google Scholar] [CrossRef] [Scilit]
- Sari, H.K.; Kopuzlu, A. On topological spaces generated by simple undirected graphs. AIMS Math. 2020, 5, 5541. [Google Scholar] [CrossRef] [Scilit]
- Noll, D. Topological spaces satisfying a closed graph theorem. Topol. Its Appl. 2024, 349, 108903. [Google Scholar] [CrossRef] [Scilit]
- Branman, B.; Domat, G.; Hoganson, H.; Lyman, R.A. Graphical models for topological groups: A case study on countable Stone spaces. Bull. Lond. Math. Soc. 2025, 57, 2311–2335. [Google Scholar] [CrossRef] [Scilit]
- Damag, F.H.; Saif, A.; Kiliçman, A.; Ali, E.E.; Mesmouli, M.B. On m-negative sets and out mondirected topologies in the human nervous system. Mathematics 2024, 12, 3763. [Google Scholar] [CrossRef] [Scilit]
- Alzubaidi, H.; Kocinac, L.D.R.; Othman, H.A. On topologies on simple graphs and their applications in radar chart methods. Axioms 2025, 14, 178. [Google Scholar] [CrossRef] [Scilit]
- Damag, F.H.; Saif, A.; Kılıçman, A.; Mesmouli, M.B.; Alhubairah, F. Upper α-graphical topological spaces with the COVID-19 form and its diffusion. Axioms 2025, 14, 84. [Google Scholar] [CrossRef] [Scilit]
- Damag, F.H.; Gul, R.; Abbas, M.; Lupaş, A.A.; Saad, K.M. Monophonic sets and rough directed topological spaces: Applications with some directed networks. AIMS Math. 2025, 10, 17623–17641. [Google Scholar] [CrossRef] [Scilit]
- Zhao, N.; Zhao, H.; Li, Y. A measure for the vulnerability of uniform hypergraph networks: Scattering number. Mathematics 2024, 12, 515. [Google Scholar] [CrossRef] [Scilit]
- Kalampakas, A. Fuzzy graph hyperoperations and path-based algebraic structures. Mathematics 2025, 13, 2180. [Google Scholar] [CrossRef] [Scilit]
- Kelley, J.L. General Topology; Courier Dover Publications: Garden City, NY, USA, 2017. [Google Scholar]
- Allendoerfer, C.B. Foundations of Differentiable Manifolds and Lie Groups, by Frank W. Warner. Am. Math. Mon. 1972, 79, 792–795. [Google Scholar] [CrossRef] [Scilit]
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.