


Abstract
We propose a class of coupled dynamical systems for solving linear inverse problems, treating both the unknown variable and an auxiliary variable representing measurement dynamics as state variables. This framework does not rely on probabilistic modeling or explicit regularization; instead, it achieves noise suppression through deterministic interactions between system variables. We analyze the theoretical properties of the systems, including stability, equilibrium behavior, and convergence for the linear system, and equilibrium stability for the two nonlinear variants. The nonlinear extensions incorporate state-dependent mechanisms that preserve equilibrium stability while enhancing convergence and robustness in practice. Numerical experiments illustrate the effectiveness of the proposed approach in estimating the unknown variable and mitigating measurement noise.
Keywords:
dynamical system; differential equation; stability of equilibrium; inverse problems; coupled dynamical system; iterative reconstruction MSC:
34A55; 34D20; 37N40; 65D18; 92C50
1. Introduction
Inverse problems arising from linear models are central to a wide range of scientific and engineering applications, including image reconstruction, system identification, and signal processing [1,2,3]. In such problems, one seeks to estimate an unknown variable from indirect or noisy observations, given a known linear operator that describes the relationship between the unknown and the data. While classical optimization-based approaches, such as least-squares and regularized minimization techniques [4,5,6], have proven effective in many settings, they often require explicit tuning of regularization parameters or prior models, and may be sensitive to noise and model mismatch [7,8]. These limitations have motivated the search for alternative methods that offer greater robustness and adaptability.
In recent years, dynamical system-based approaches have emerged as a powerful alternative in the field of inverse problems. These methods reformulate estimation or optimization processes as time-evolving systems of differential equations, offering insights into convergence behavior and robustness to noise [9,10]. The flexibility and interpretability of such continuous-time models make them particularly appealing in applications where noise suppression and real-time dynamics are crucial. Furthermore, recent developments in neural differential equations and physics-informed machine learning have reinvigorated interest in ODE-based modeling for inverse problems and data assimilation [11,12].
In this work, we propose a novel dynamical system for solving linear inverse problems, with the aim of jointly estimating the unknown variable and suppressing the effects of measurement noise. Our approach introduces an auxiliary variable representing the measurement dynamics, which results in a system of coupled ordinary differential equations that simultaneously evolve the estimate and a smoothed representation of the data. This formulation is conceptually similar to augmented state estimation (ASE), which is frequently employed in sequential estimation methods, such as the Kalman filter [13].
While our approach may outwardly resemble ASE, it fundamentally differs in both theoretical foundations and practical implementation. Classical techniques in this category are typically probabilistic, relying on recursive Bayesian updates with explicit noise models and covariance propagation. In contrast to Kalman-type filters, our method is fully deterministic: instead of modeling measurement noise explicitly, it implicitly mitigates its effect through the evolution of a carefully designed dynamical system. This enables both estimation and noise suppression via the system dynamics alone, without recourse to probabilistic modeling. Such a formulation defines a novel class of methods that have an ASE-like structure but operate entirely within a deterministic framework.
In addition to presenting this linear coupled dynamical formulation, we extend our method by introducing two nonlinear variants that further enhance its convergence and robustness. The first nonlinear system draws inspiration from expectation–maximization (EM) techniques and incorporates state-dependent adaptive mechanisms into the dynamics [14]. The second is based on multiplicative algebraic (MA) update schemes used for computed tomography (CT) image reconstruction. While the underlying vector field of the dynamical system is not strictly multiplicative, the discretization of the system using a multiplicative-type Euler method leads to an iteration formula with a multiplicative structure, thereby ensuring properties such as stability and non-negativity [15,16].
The remainder of the paper is organized as follows. In Section 2, we describe the proposed dynamical systems in detail and analyze their theoretical properties, including stability conditions and equilibrium behavior. Section 3 provides numerical experiments on tomographic image reconstruction, illustrating the noise suppression capabilities of the method. In Section 4, we discuss the implications of the results and provide a comparison with conventional techniques based on experimental outcomes. Finally, Section 5 concludes the paper and outlines potential directions for future work.
2. Proposed Systems
We propose a novel dynamical approach for solving linear inverse problems with nonnegative unknowns, of the form
where is a known linear operator, is the observed data (possibly noisy), and is the variable to be estimated. Here, R denotes the set of real numbers, with and denoting its nonnegative and strictly positive subsets, respectively; the notation will appear in later sections. We say that the inverse problem based on the linear model in Equation (1) is consistent if there exists at least one vector such that . In this study, we assume that the true solution e is nonnegative, reflecting the physical constraints of the problem. Our method is based on a class of coupled initial value problems defined by systems of differential equations. We introduce a linear formulation and then propose two distinct nonlinear extensions, each designed to enhance convergence and stability properties. The first extension is an EM-type nonlinear system that incorporates state-dependent dynamics, as is done in the expectation–maximization algorithm [15,17]. The second is an MA-type nonlinear system that is based on MA schemes commonly used in iterative solution methods. These systems offer a flexible and rigorous framework for developing solution methods for inverse problems.
2.1. Linear Coupled Dynamical System
We begin by presenting the linear version of the coupled dynamical system, which forms the basis of our method. The system is defined by the following differential equations with respect to the independent variable t, which is assumed to satisfy :
where is the transpose of A, is a real scalar parameter, and is a positive scalar. The matrix is diagonal with entries
that is, , where denotes the vector of these diagonal elements. The auxiliary variable , initialized as , can be interpreted as a dynamically evolving estimate of the data, which interacts with the unknown x in a feedback mechanism. This coupled system induces a regularizing effect that naturally suppresses the influence of noise in the data. In the special case where , the variable remains fixed at p for all , and the system reduces to a dynamics governed solely by the variable x.
Equation (2) can be rewritten as a vector differential equation in the following form:
where E and 0 denote an identity matrix and a zero matrix of appropriate dimension, respectively. In what follows, we analyze the stability of the equilibrium of the coupled linear differential system given in Equation (4). Assuming that the inverse problem in Equation (1) is consistent, i.e., there exists a vector such that , the system admits an equilibrium , which we take as the basis for our stability analysis.
The stability of this equilibrium is determined by the eigenvalues of the Jacobian matrix at the equilibrium, which takes the form , where
Here, is a block-diagonal matrix composed of a diagonal matrix and the identity matrix E, and thus is diagonal with strictly positive entries. Therefore, the spectral condition for to have all eigenvalues in the open left-half plane is equivalent to that for . Accordingly, we focus on the eigenvalue distribution of .
This leads to the following theorem, which provides a necessary and sufficient condition for the asymptotic stability of the equilibrium.
Theorem 1.
Consider the dynamical system given by Equation (4), where and . Let μ denote the eigenvalues of Γ, and be the smallest eigenvalue of . Suppose that there exists such that . Then, the equilibrium is asymptotically stable if and only if the following condition holds: If is not an eigenvalue of Γ, then ; if is an eigenvalue of Γ, then .
Proof.
Let , where C denotes the set of complex numbers, be an eigenvalue of the matrix . Then satisfies the characteristic equation,
where E is an identity matrix of appropriate size. Using the block structure of , we apply the Schur complement formula. Assume first that , so that the lower-right block of is invertible. Then the determinant becomes
Denote by an eigenvalue of the symmetric positive semidefinite matrix . Then, the corresponding scalar eigenvalue equation becomes
Solving for , we obtain the quadratic formula
This shows that the eigenvalues lie in the open left-half complex plane (i.e., have negative real parts) if and only if holds for all . Since the left-hand side is strictly increasing with respect to , this condition is equivalent to .
Next, we turn to the special case where . In this case, , so the Schur complement used above is not applicable. However, we can directly observe the following: since , this eigenvalue lies in the open left-half of the complex plane if and only if . The eigenvalue may exist depending on the choice of , , and A, but its existence is not essential to the proof. It suffices to note that if it does exist, the condition ensures its contribution to asymptotic stability.
In summary, all eigenvalues of lie in the open left-half complex plane if and only if either (i) and , or (ii) is among the eigenvalues of , and . □
We further examine the nature of the convergence by analyzing the discriminant of Equation (5), namely, . Depending on its sign, the system exhibits the following behavior:
- If the discriminant is positive, the eigenvalues will be real, distinct, and negative, and the system will show monotonic convergence.
- If the discriminant is zero, the eigenvalues will coincide at the same real negative value, and the system will show non-oscillatory convergence.
- If the discriminant is negative, the eigenvalues will form a complex conjugate pair with negative real parts, and the system will show oscillatory but asymptotically stable dynamics.
This characterization of the eigenvalues offers a complete description of the asymptotic stability and convergence behavior of the system, highlighting the roles of , , and the operator A. To complement this spectral analysis, we now present a constructive proof of stability based on Lyapunov’s direct method [18]. In contrast to eigenvalue-based arguments, the Lyapunov approach offers additional insight into the dissipative structure of the dynamics and lays the foundation for its extension to the nonlinear setting in the next section. The following theorem establishes asymptotic stability of the linear system using a quadratic Lyapunov function.
Theorem 2.
Consider the linear coupled dynamical system defined in Equation (2). Suppose that , , and there exists such that . Then, the equilibrium is asymptotically stable.
Proof.
Let us consider the dynamical system defined in Equation (2). Since there exists a vector such that by assumption, is an equilibrium of the system. We introduce the following candidate Lyapunov function:
where denotes the Euclidean norm. This function is nonnegative and vanishes if and only if and , that is, when . Since , the only point satisfying this condition is .
We compute the time derivative of along trajectories of the system:
Substituting the right-hand sides of Equation (2) into the expression, we obtain:
where denotes a diagonal matrix with entries for , i.e., the element-wise square root of .
Since , the function is non-increasing along system trajectories. Moreover, if and only if both and . Solving these equations, we find that the only point satisfying both conditions is . Hence, all trajectories converge to this equilibrium, which implies that it is asymptotically stable. □
2.2. Nonlinear Coupled Dynamical Systems
In addition to the linear coupled system described above, we consider two nonlinear extensions that incorporate logarithmic, state-dependent terms. These nonlinear systems are designed to enhance dynamical behavior and improve robustness in the presence of variability or noise. Both systems are constructed as coupled initial value problems, sharing the same variables and parameters introduced in the linear case.
The first system, which we refer to as the EM-type system, is given by the following:
for , , and , with initial conditions for all j and . Here, denotes the dot product between the column vector corresponding to the ith row of the matrix A and the vector . Notably, in the case , this system reduces to x-only dynamics that represent a continuous analog [19] of the expectation–maximization algorithm used in iterative image reconstruction in CT.
The second system, referred to as the MA-type system, is constructed with an alternative coupling structure and a correction mechanism inspired by algebraic reconstruction methods. It is defined as:
with the same initial conditions as before. In contrast to the EM-type dynamics, setting in this system effectively disables the y-dynamics, yielding an x-only system that coincides with the continuous analog of the (simultaneous) multiplicative algebraic reconstruction technique [20,21] (MART), a method originally developed for iterative CT image reconstruction.
Next, we present theoretical results for the nonlinear coupled dynamical systems introduced above. Under mild assumptions, we show that both systems converge to the desired solution of the inverse problem when it is consistent. Specifically, Theorem 3 establishes the convergence property for the EM-type system defined in Equation (7), while Theorem 4 treats the MA-type system described in Equation (8).
Theorem 3.
Consider the nonlinear coupled dynamical system defined in Equation (7). Assume , , and that there exists such that . Then the point is an equilibrium and is asymptotically stable.
Proof.
First, it is straightforward to verify that is an equilibrium of the system. Since the initial condition at is assumed to lie in , and the vector field is well-defined and smooth in this domain, the uniqueness of solutions guarantees that trajectories remain in for all . In particular, the flow cannot cross the invariant subspaces defined by or for any and .
Now, we define the following nonnegative function , which is well-defined for all and , as a Lyapunov candidate:
where denotes the Kullback–Leibler divergence.
To show that , we analyze each term in the derivative of along the trajectories of the system. First, observe that the time derivative of V is given by:
We begin with the first term. Substituting the expression for from Equation (7), we obtain
Let us define
and
Then, the first and second terms of Equation (11) become
and
respectively, because for and hold. By adding the two inequalities in (12) and (13), we deduce that the first term on the right-hand side of Equation (10) is less than or equal to zero.
Next, we analyze the second and third terms on the right-hand side of Equation (10). Using the expression in Equation (7), we have
From the above discussion, we conclude that
and equality holds if and only if for all i, i.e., at the equilibrium. Thus, is non-increasing along the trajectories of the system, and the equilibrium is asymptotically stable. □
Theorem 4.
For the nonlinear coupled dynamical system given by Equation (8), suppose that , , and there exists satisfying . Then, the point constitutes an asymptotically stable equilibrium.
Proof.
The proof proceeds along similar lines as that of Theorem 3, with the key difference lying in the choice of the Lyapunov function.
As before, it is straightforward to verify that is an equilibrium of the system (8) and that the trajectories remain in the positive orthant because of the well-defined and smooth vector field and positive initial conditions.
We define the Lyapunov candidate function as
and write it explicitly as
Now, we can compute the time derivative along trajectories of the system (8). Through direct calculation, we can show that holds and that equality occurs if and only if , thereby establishing the asymptotic stability of the equilibrium. Specifically, we have
with equality if and only if . This confirms that is an asymptotically stable equilibrium of the system (8). □
3. Numerical Experiments
To evaluate the performance and properties of the proposed coupled dynamical systems, we conducted numerical experiments on representative linear inverse problems. Our experiments focused on examining the convergence behavior, noise suppression capabilities, and qualitative reconstruction accuracy of each method.
Below, we describe the discretization procedure and experimental setup used throughout the experiments. In particular, we discretized the continuous-time systems introduced in Section 2 by using forward Euler schemes to yield iterative update rules. After that, we describe the tests of the resulting discrete systems under controlled conditions with synthetic data.
3.1. Discrete Systems
Three discrete dynamical systems are formulated, corresponding to the one linear and two nonlinear continuous-time models introduced in Section 2. These systems involve two state variables: , representing the unknown to be estimated, and , an auxiliary state variable that evolves to capture a denoised representation of the measured data.
The time domain is discretized with a fixed step size of 1, which corresponds to the standard implementations of MLEM and MART when the parameter is set to 0. The discrete time index is denoted as , where N is the total number of iterations. The continuous-time variables and are represented in discrete time as and , respectively.
Each update rule was applied component-wise for all and , where J is the dimension of the unknown vector , and I is the dimension of the observed data vector p and the auxiliary variable .
- (1)
- Linear Discrete System.
This system was obtained by applying the additive Euler method to the linear coupled ODEs. The update rules are as follows:
where denotes a standard clipping (non-negativity projection) operator applied to each scalar component.
- (2)
- EM-Type Nonlinear Discrete System.
This system incorporates multiplicative-type updates inspired by the expectation–maximization algorithm:
- (3)
- MA-Type Nonlinear Discrete System.
This system employs exponential updates as is done in multiplicative algebraic methods:
In all three systems, the parameters and are tunable and play an essential role in determining the convergence rate and stability of the system. Their specific values are discussed later in conjunction with each experiment.
3.2. Experimental Setup
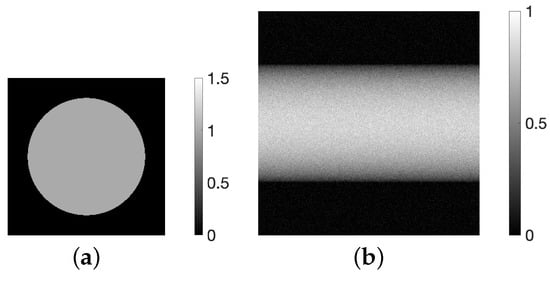
Numerical experiments were performed on a representative linear inverse problem: tomographic image reconstruction. As a ground-truth image, we used a synthetic disc phantom with a spatial resolution of , corresponding to pixels in the image domain (see Figure 1a). This phantom has a simple structure with flat regions of constant intensity. We chose this design to clearly evaluate how well the proposed method can suppress artifacts caused by measurement noise.
Figure 1.
(a) Disc digital phantom image and (b) its simulated noisy projection, displayed as a two-dimensional grayscale image (sinogram) normalized to a maximum of 1.
The projection data were generated according to a linear model , where denotes the true phantom image, and is additive noise drawn from a Gaussian distribution. The projection geometry simulated a 180-degree parallel-beam scan with 360 projection directions (uniformly spaced at 0.5-degree intervals) and 365 detector bins per direction, resulting in measurements in total. Figure 1b shows the resulting noisy sinogram, where the noise level was adjusted to yield a signal-to-noise ratio (SNR) of 20 dB.
For all iterative methods considered in the experiments, the initial estimate was set uniformly across all pixels based on the average projection intensity:
The abbreviations listed in Table 1 will be used to refer to the various reconstruction algorithms that we tested, which included classical iterative methods and the proposed coupled dynamical system-based approaches.
Table 1.
Abbreviations and descriptions of proposed and classical methods.
All numerical computations were performed using a custom implementation developed in MATLAB R2023a (MathWorks, Natick, MA, USA). The experiments were run on a machine equipped with an Apple M2 Max chip (Apple Inc., Cupertino, CA, USA) and 64 GB of RAM.
3.3. Experimental Results
We evaluated the proposed and conventional reconstruction methods using synthetic projection data. In what follows, the reconstructed image at iteration n is denoted by , and the ground-truth image is denoted as e. Here, e was assumed to be known in all of the experiments, and unless otherwise noted, white Gaussian noise was added to the projection data so that the SNR would be 20 dB.
We evaluated the reconstruction accuracy using the following discrepancy measure:
which quantifies the Euclidean distance between the reconstructed image z and the ground truth e. A smaller value of indicates a more accurate reconstruction at iteration n.
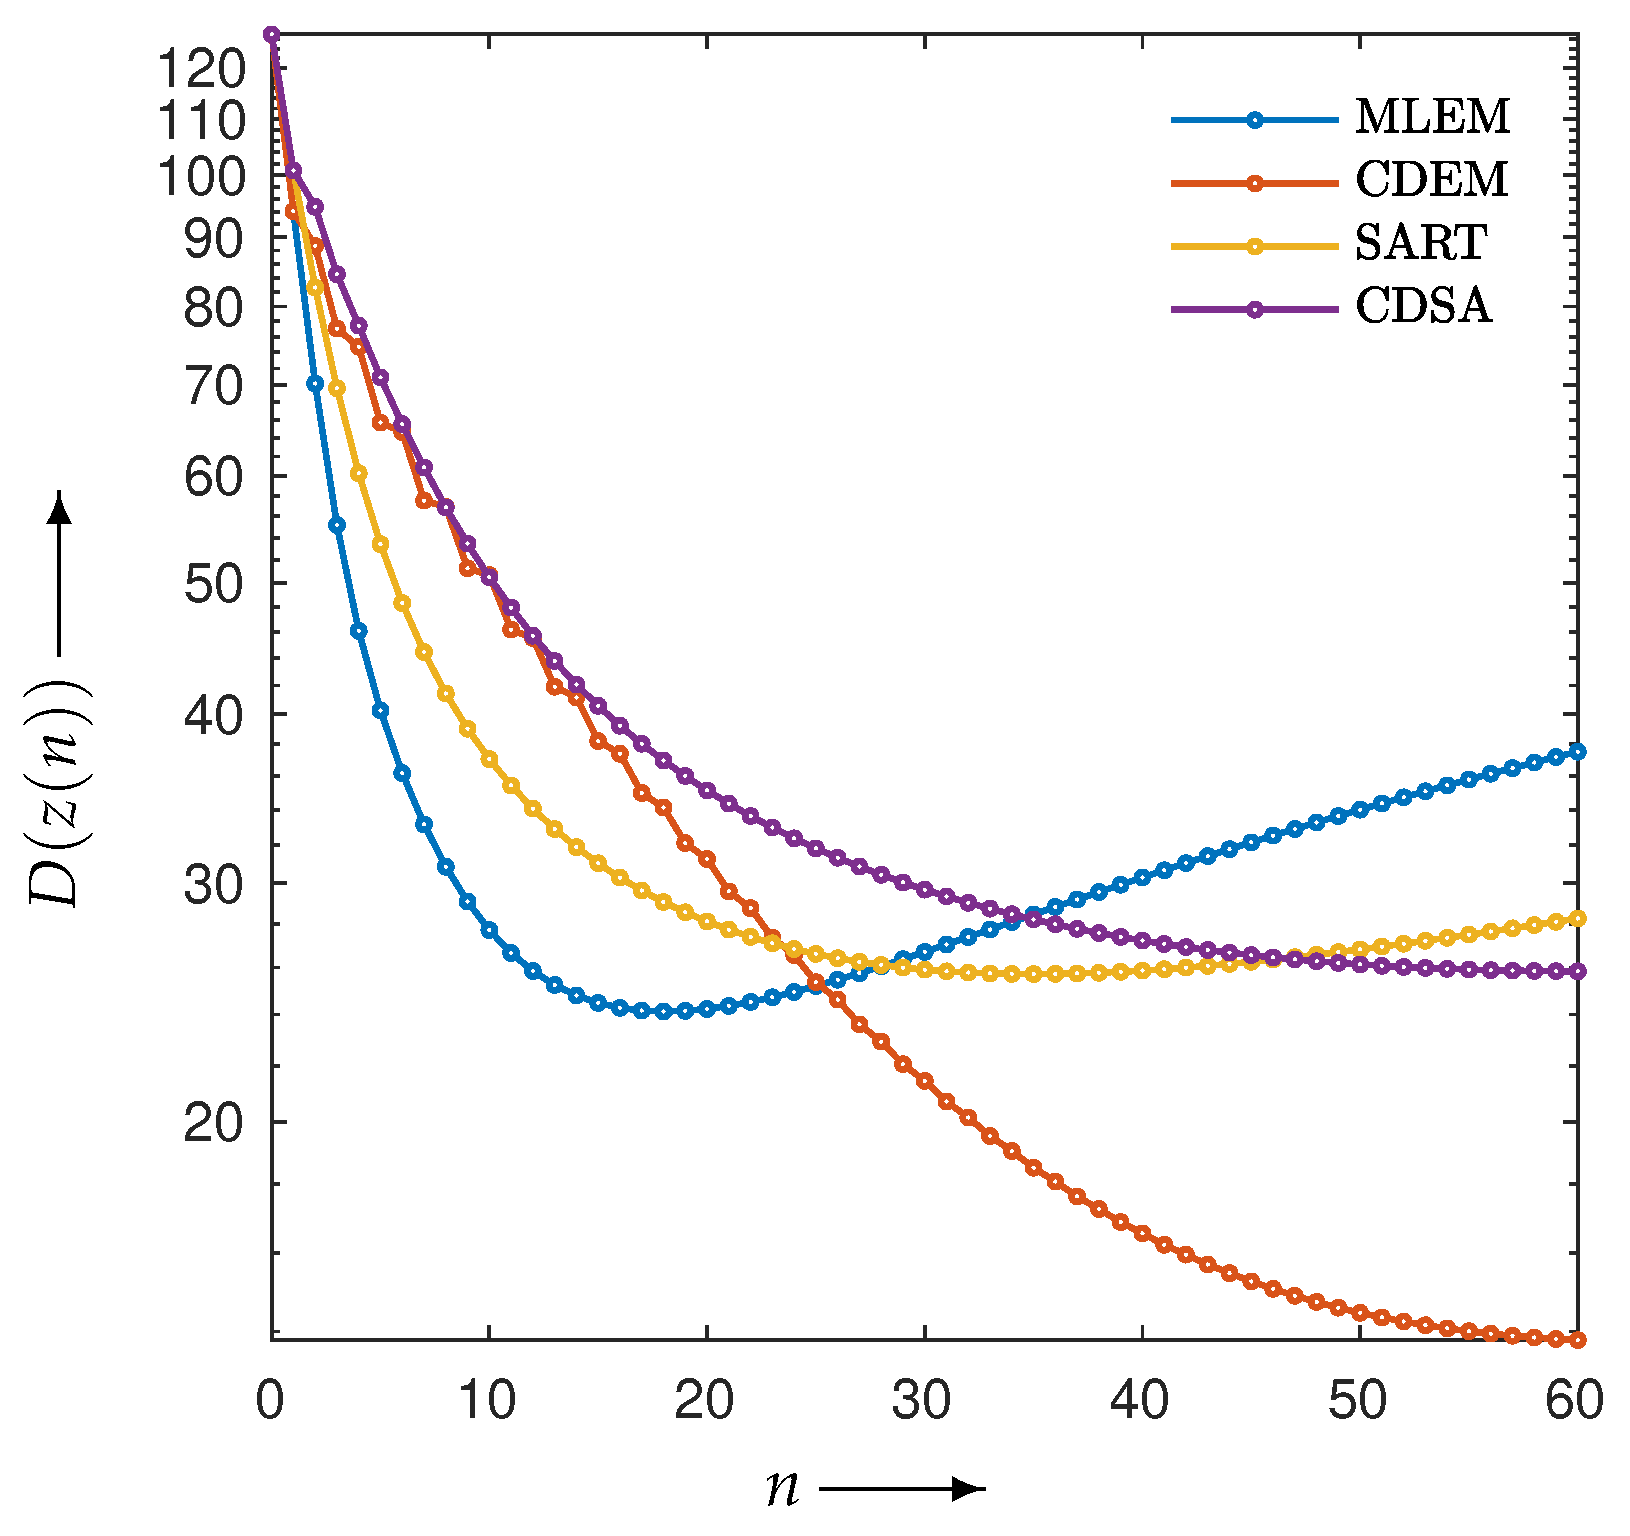
Figure 2 shows the evolution of over the iterations of MLEM, CDEM, SART, and CDSA. Among them, CDEM reached a significantly lower final discrepancy measure. At 60 iterations, the computation time was 6.67 s for MLEM and 9.12 s for CDEM, an increase of approximately 37%. This difference is due to the extended state variables in CDEM. We will discuss this in Section 4.
Figure 2.
Evaluation metric as a function of iteration number n for image reconstructions made using MLEM, CDEM, SART, and CDSA with 20 dB noisy projections.
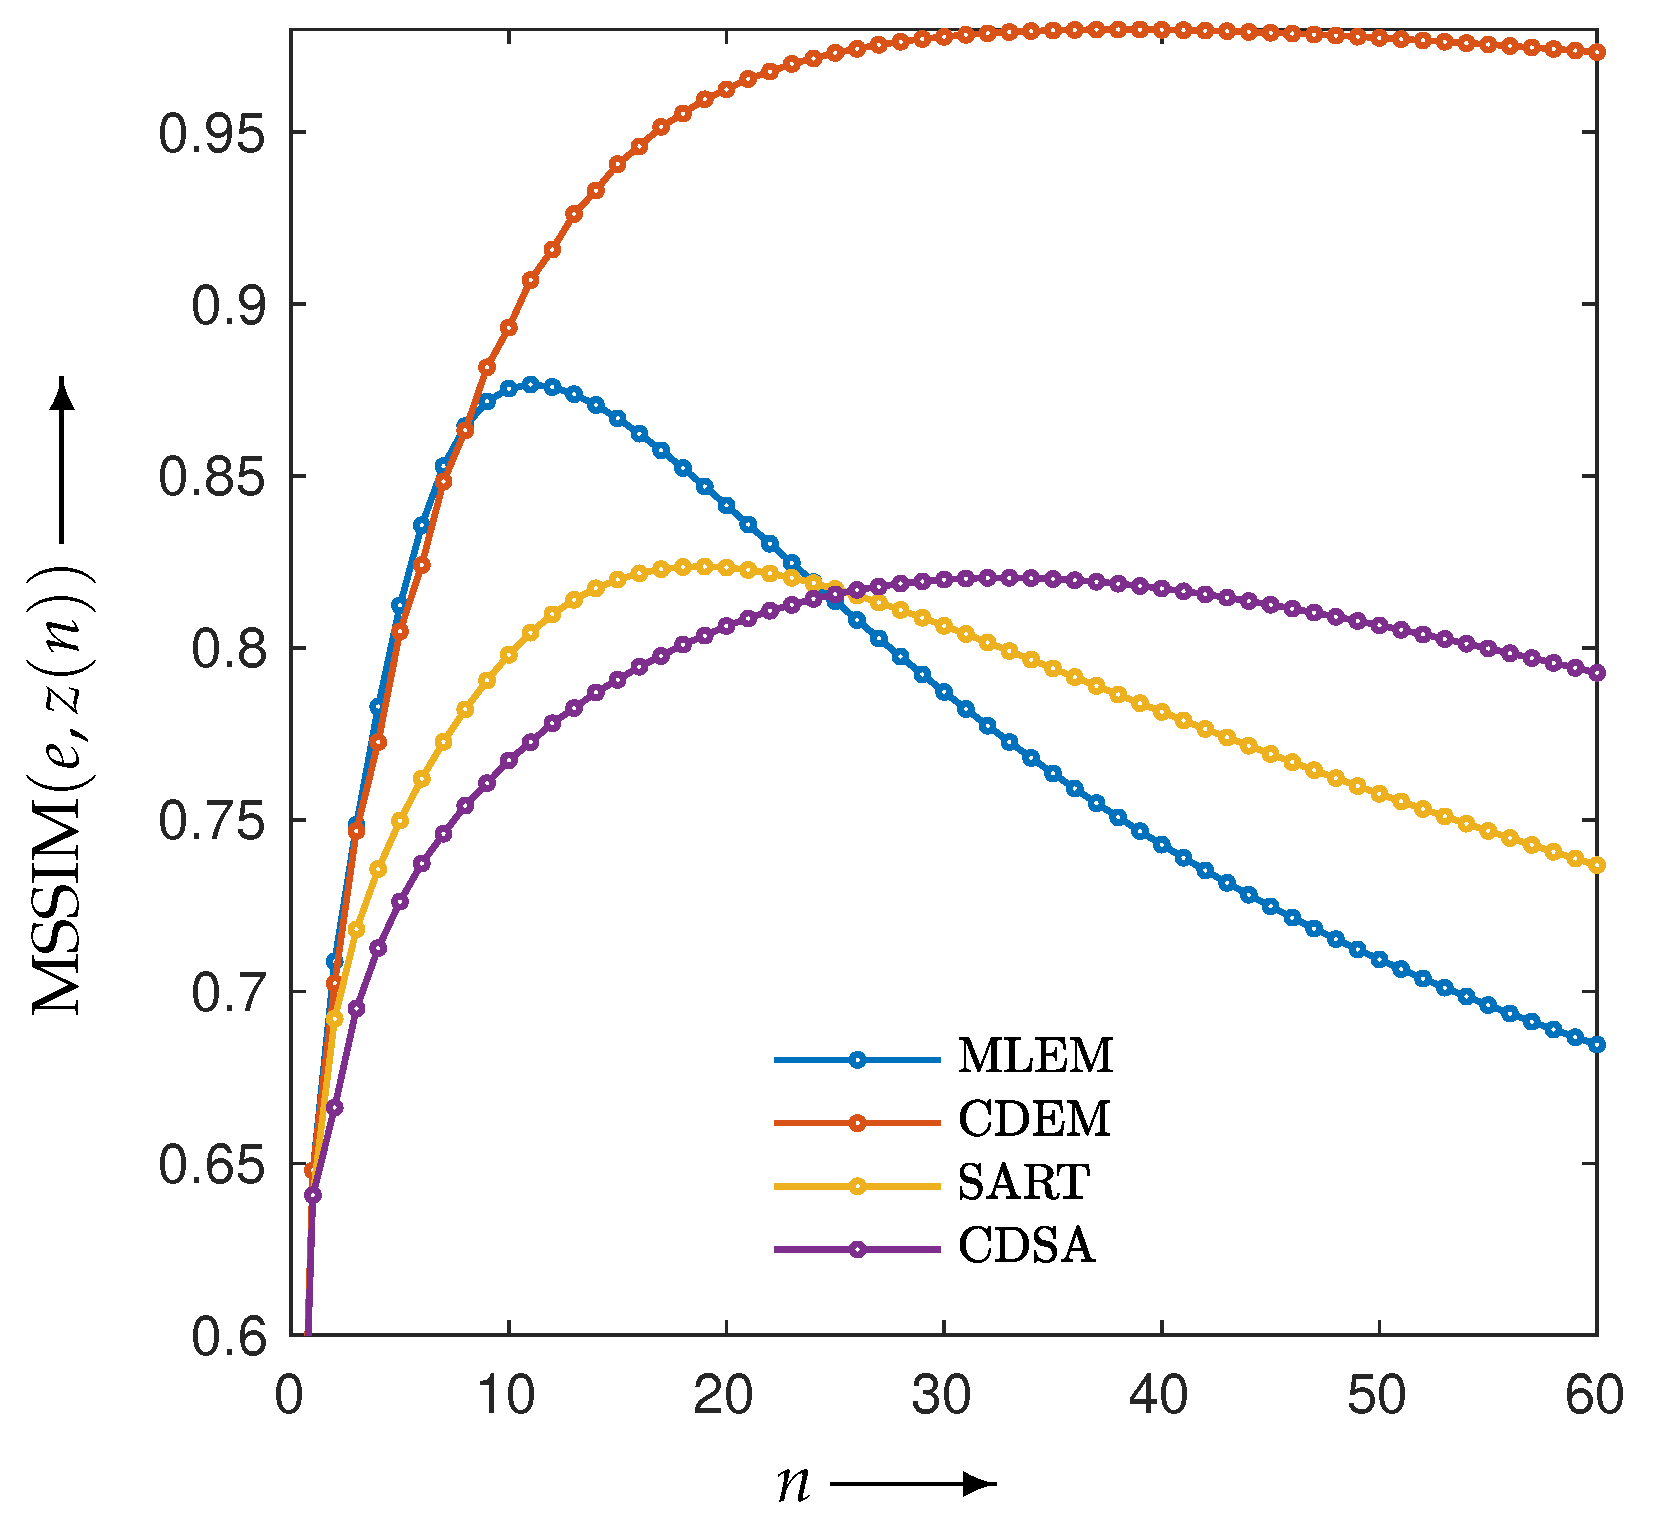
To assess the perceptual quality of the reconstructions, we computed the multi-scale structural similarity index measure (MS-SSIM) between the reconstructed image and the ground truth e, denoted by . MS-SSIM is a perceptually motivated measure that quantifies image similarity across multiple resolution levels. It computes the standard SSIM score at five progressively downsampled versions of the image pair and combines them into a single value by using fixed relative weights—4.48%, 28.56%, 30.01%, 23.63%, and 13.33%—as proposed by Wang et al. [22], reflecting the importance of each scale. A higher MS-SSIM value indicates greater structural similarity between the two images.
Figure 3 shows the MS-SSIM values over the iterations for the four methods. At , the MS-SSIM values for MLEM, CDEM, SART, and CDSA are 0.685, 0.973, 0.737, and 0.793, respectively. Among these, CDEM achieves the highest similarity score, followed by CDSA, SART, and MLEM.
Figure 3.
MS-SSIM values as a function of iteration number n for image reconstructions made using MLEM, CDEM, SART, and CDSA with 20 dB noisy projections.
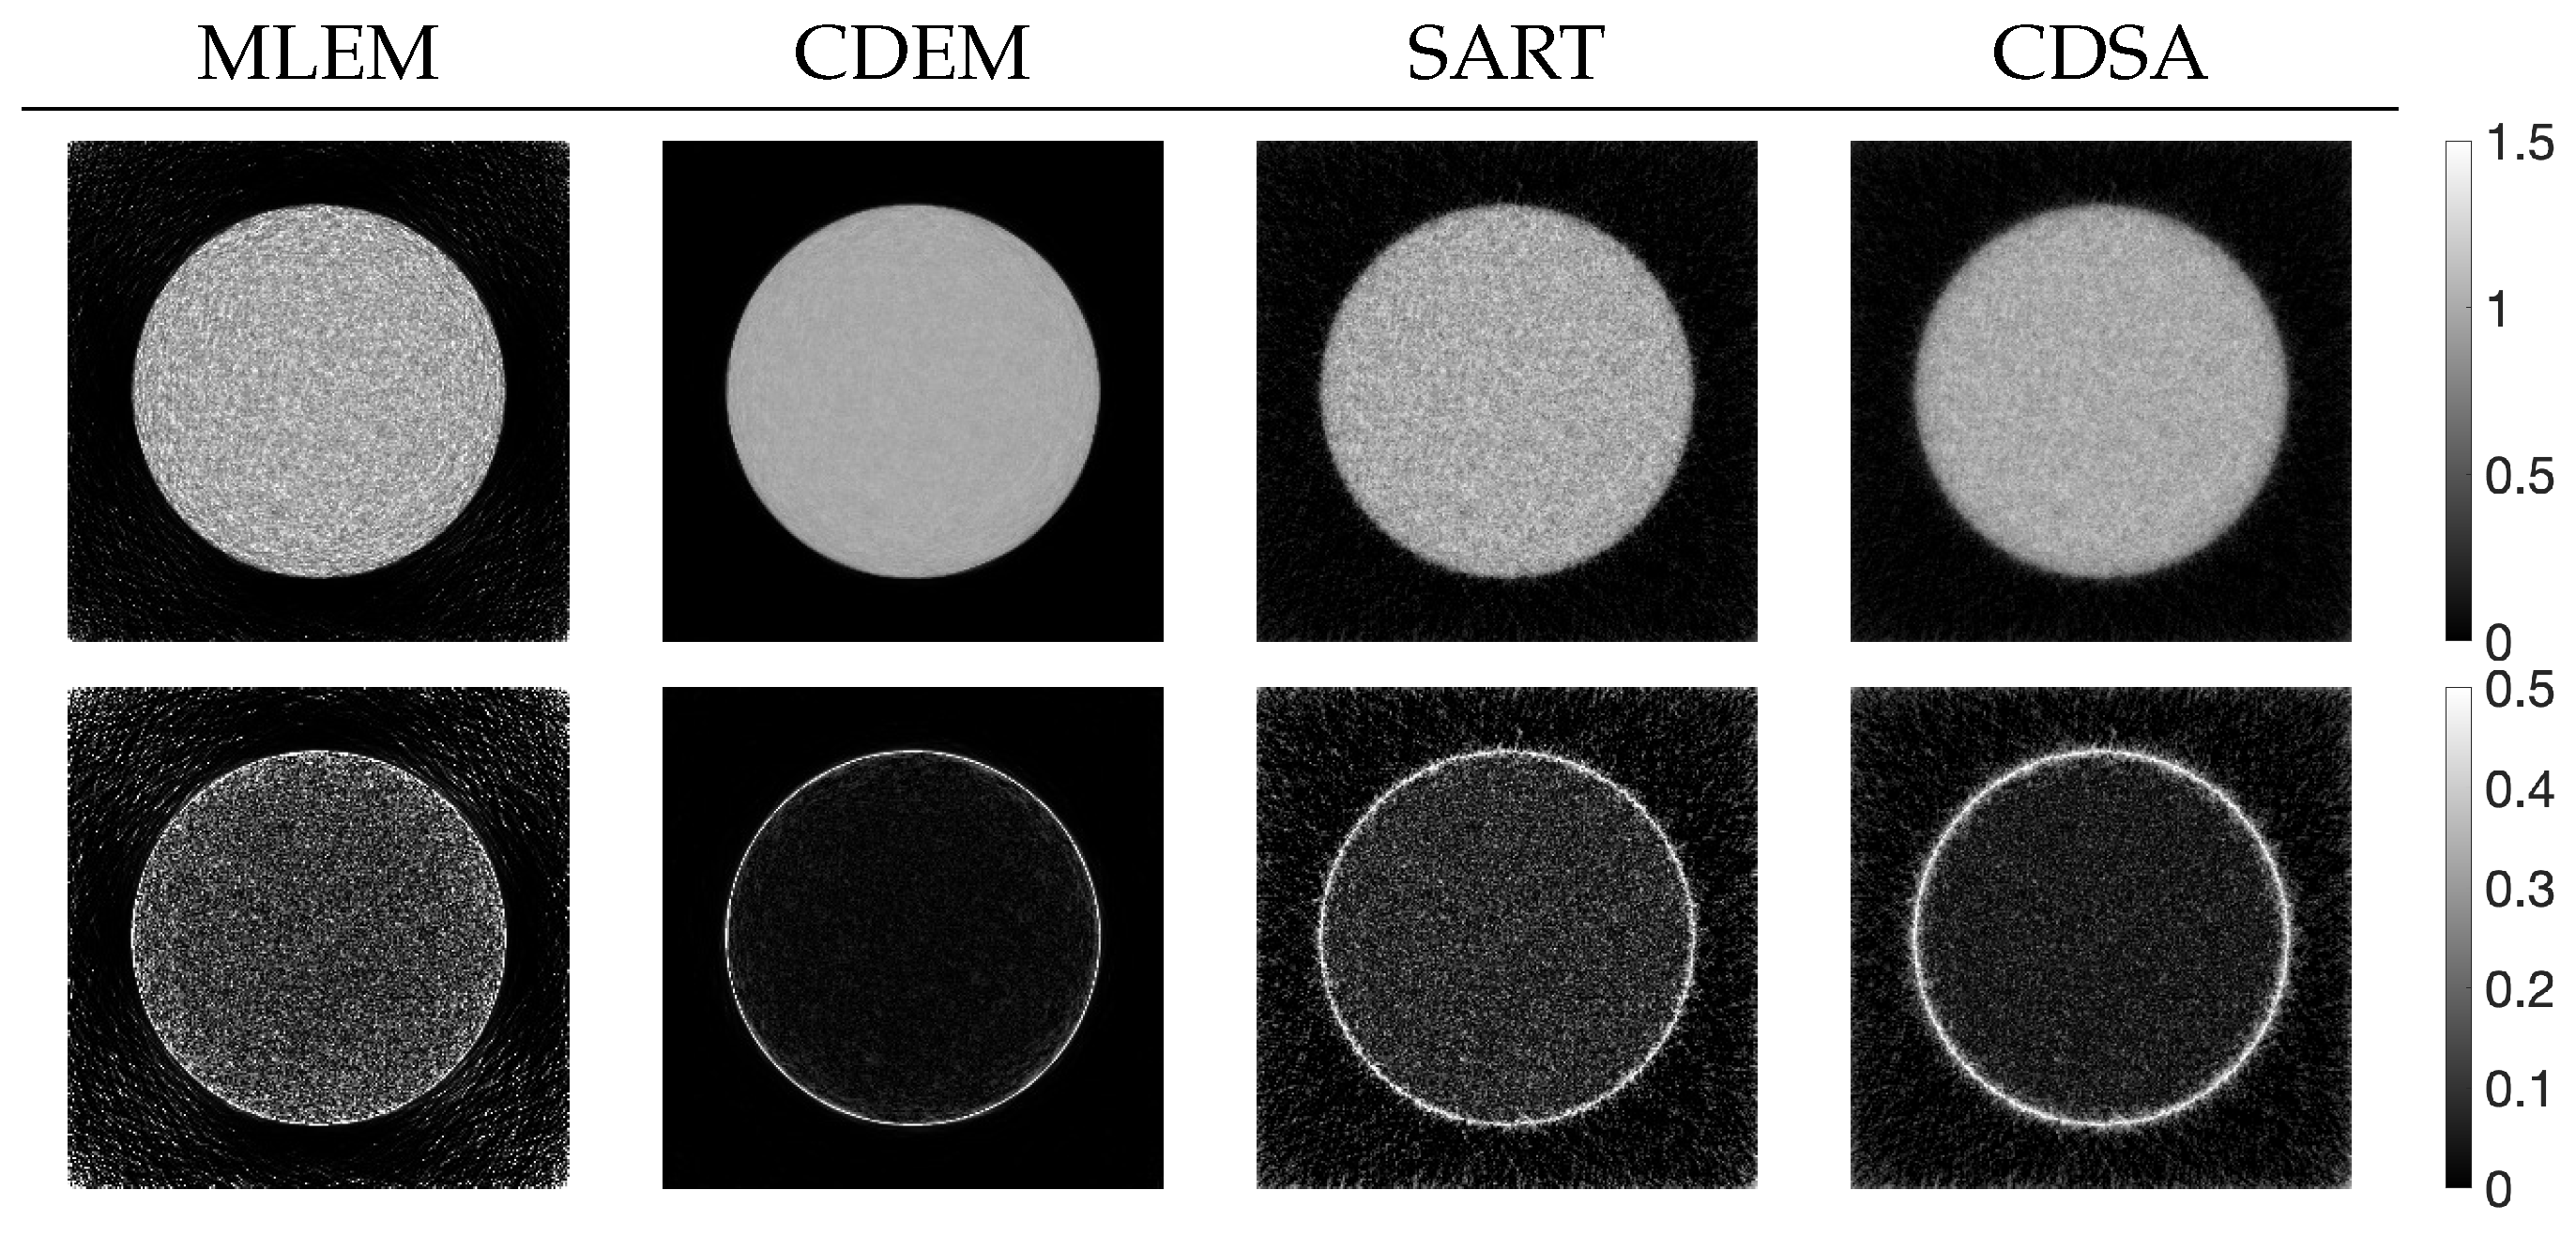
Figure 4 provides visual comparisons of the reconstructed images at iteration , along with corresponding difference images (i.e., absolute differences from the ground truth). The upper row shows the reconstructions obtained using MLEM, CDEM, SART, and CDSA, while the lower row highlights the residual artifacts. CDEM produces visually superior results with reduced noise and structural distortion, and its difference image confirms minimal discrepancy from the ground truth. CDSA also shows improved noise suppression compared with SART and MLEM.
Figure 4.
Images reconstructed using MLEM, CDEM, SART, and CDSA (upper) and their corresponding difference images (lower).
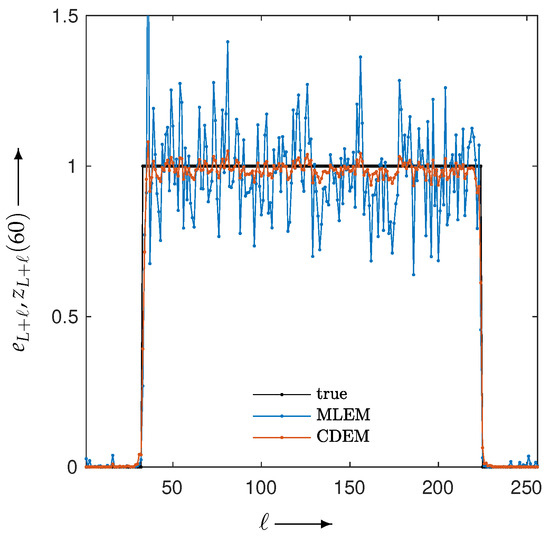
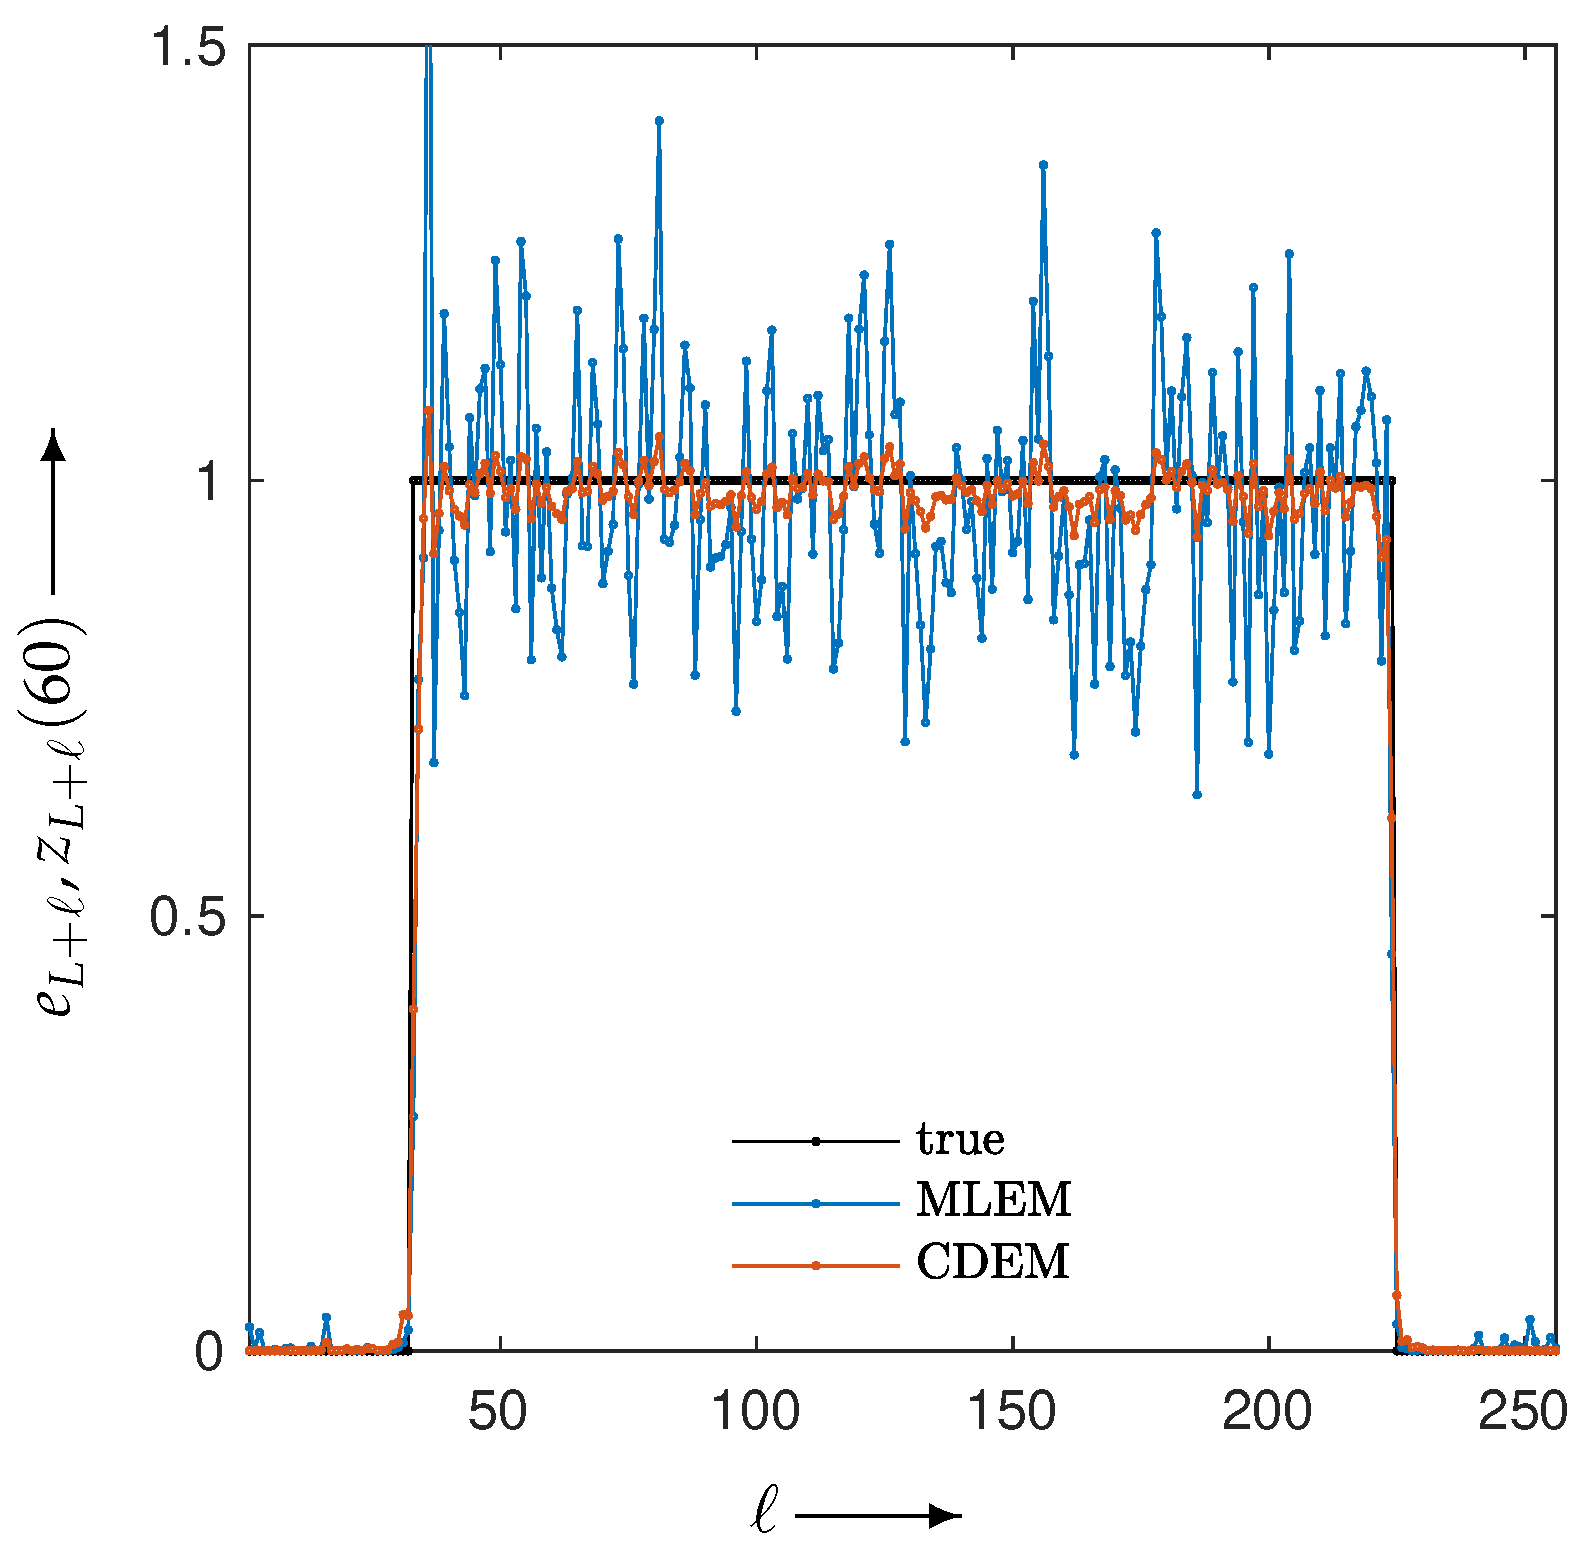
Further quantitative evaluations are presented in Figure 5, which shows the intensity profiles along the central horizontal line (row 128) for the images reconstructed by MLEM and CDEM and the ground truth. The CDEM profile is notably closer to the true values than that of MLEM, and it exhibits much lower variance in flat regions of the ground truth. This indicates that CDEM better preserves both structural features and uniform areas with reduced noise.
Figure 5.
Intensity profiles along the central horizontal line (row 128) for MLEM and CDEM reconstructions, along with that of the ground truth. The plotted values are for the reconstructed images and for the ground truth, where is the column-major offset to row 128, and indexes the pixels within that row.
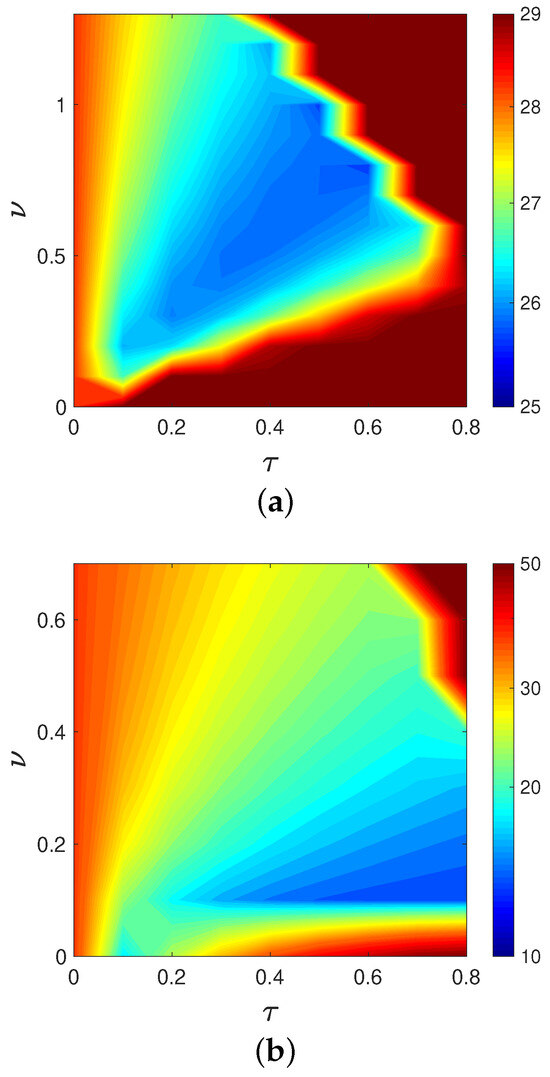
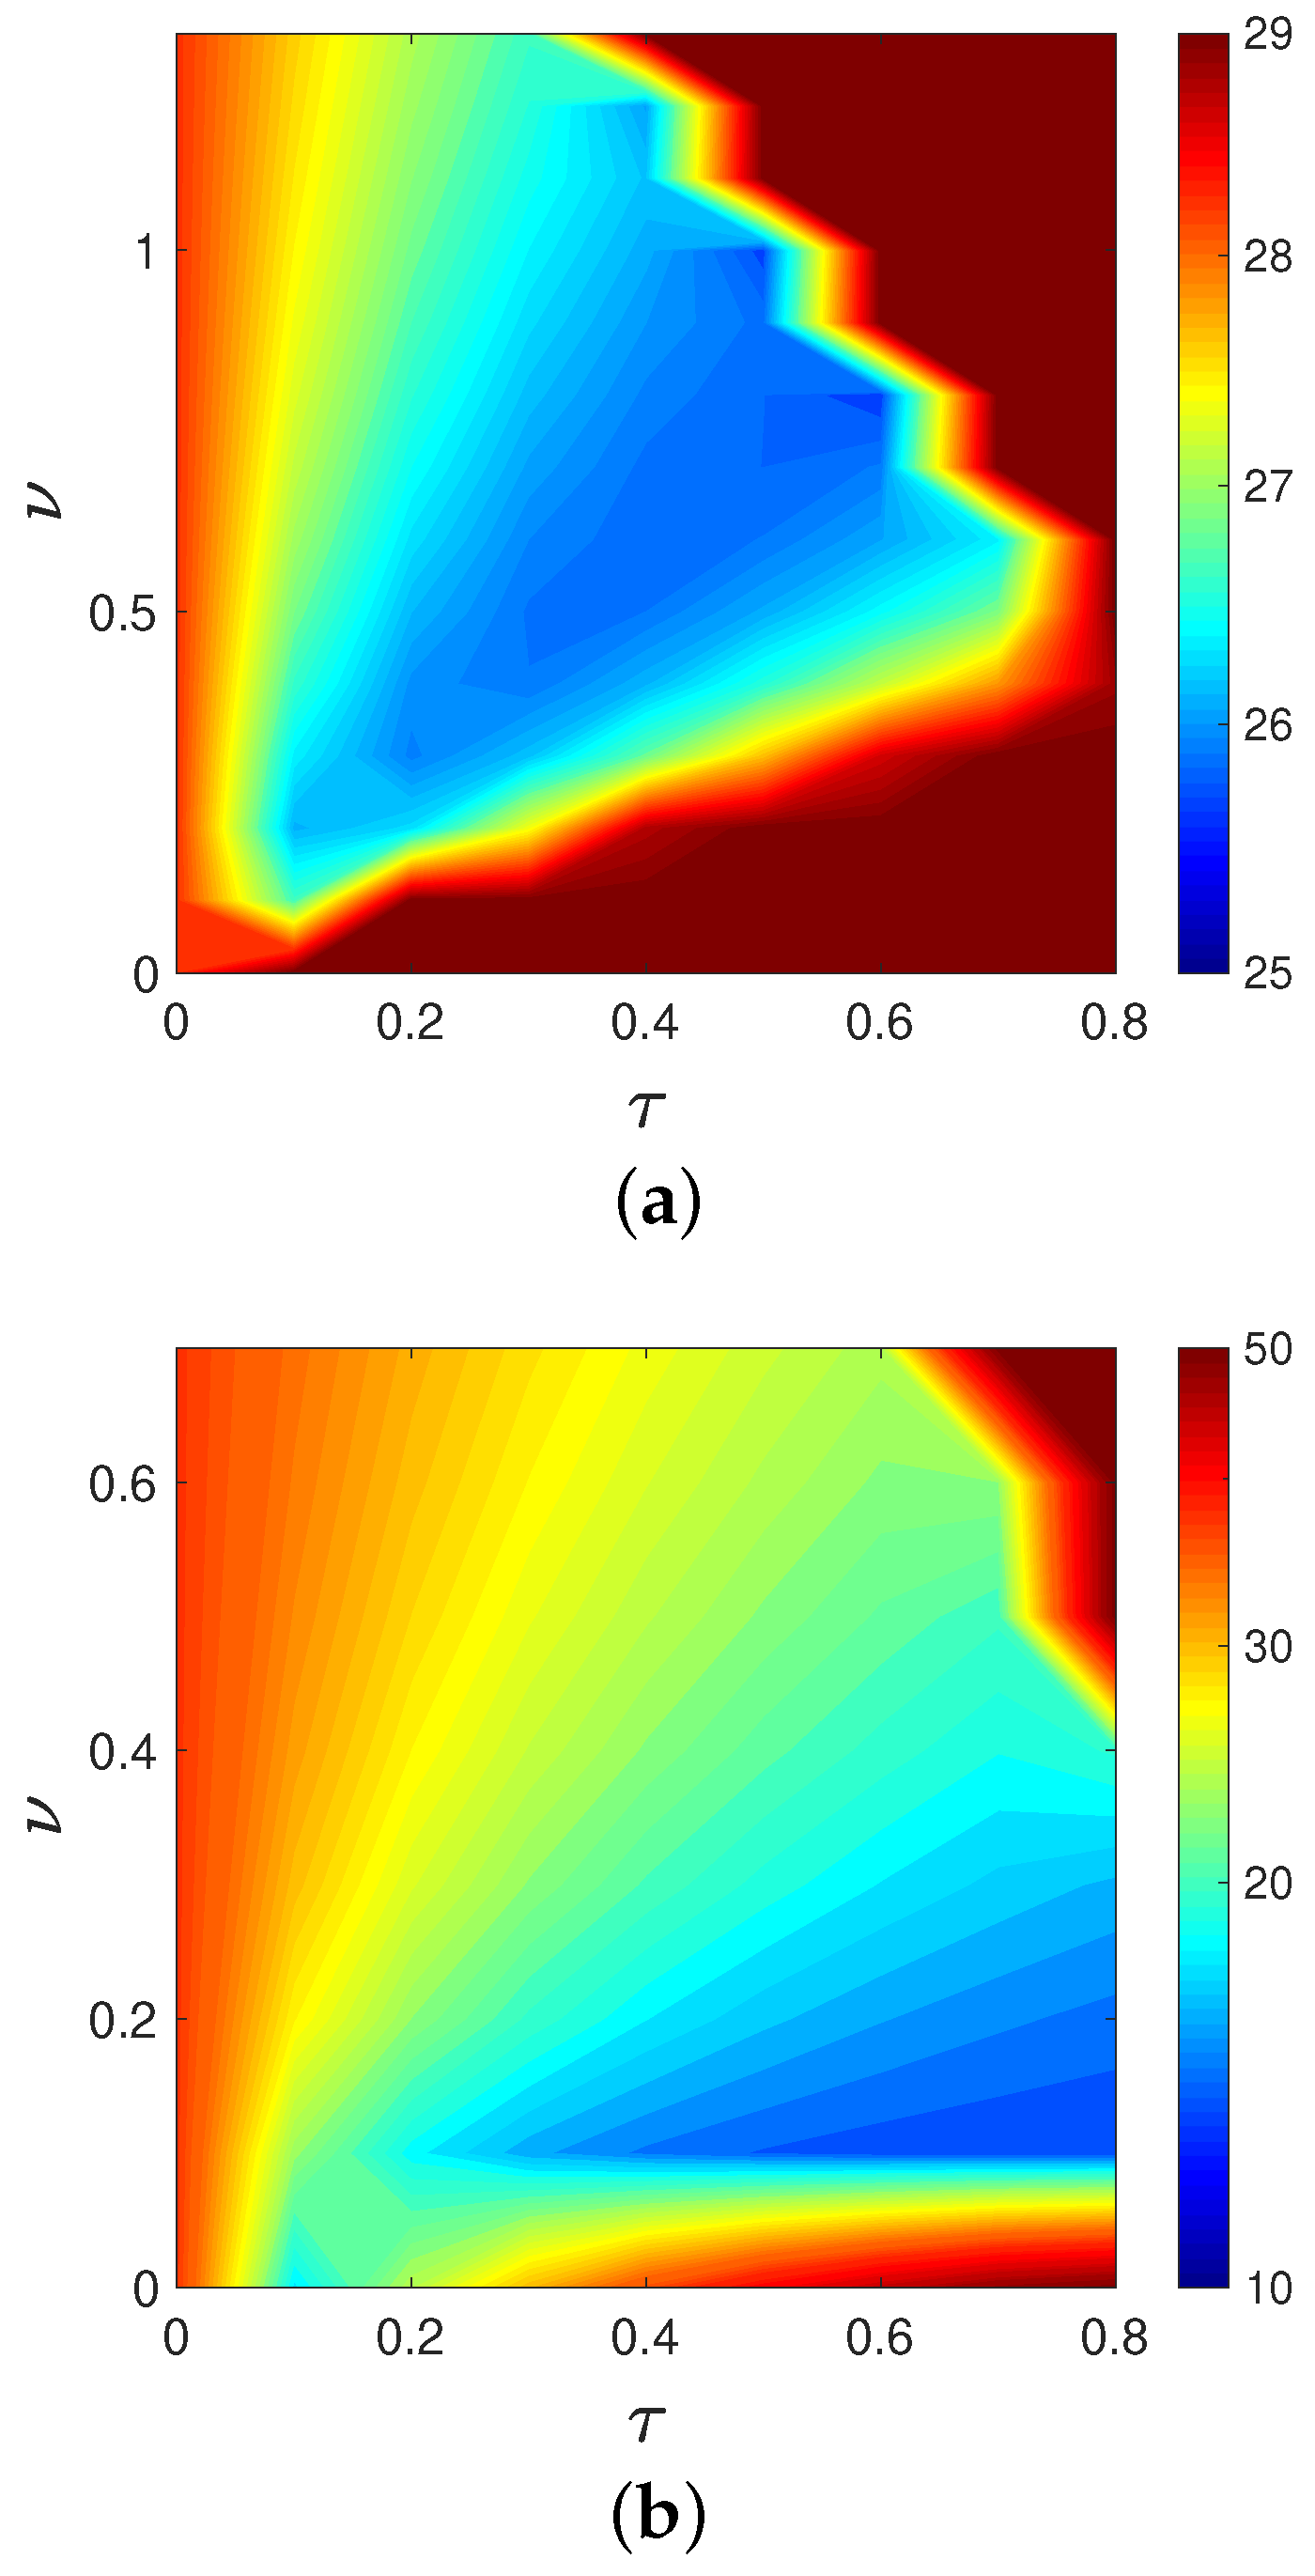
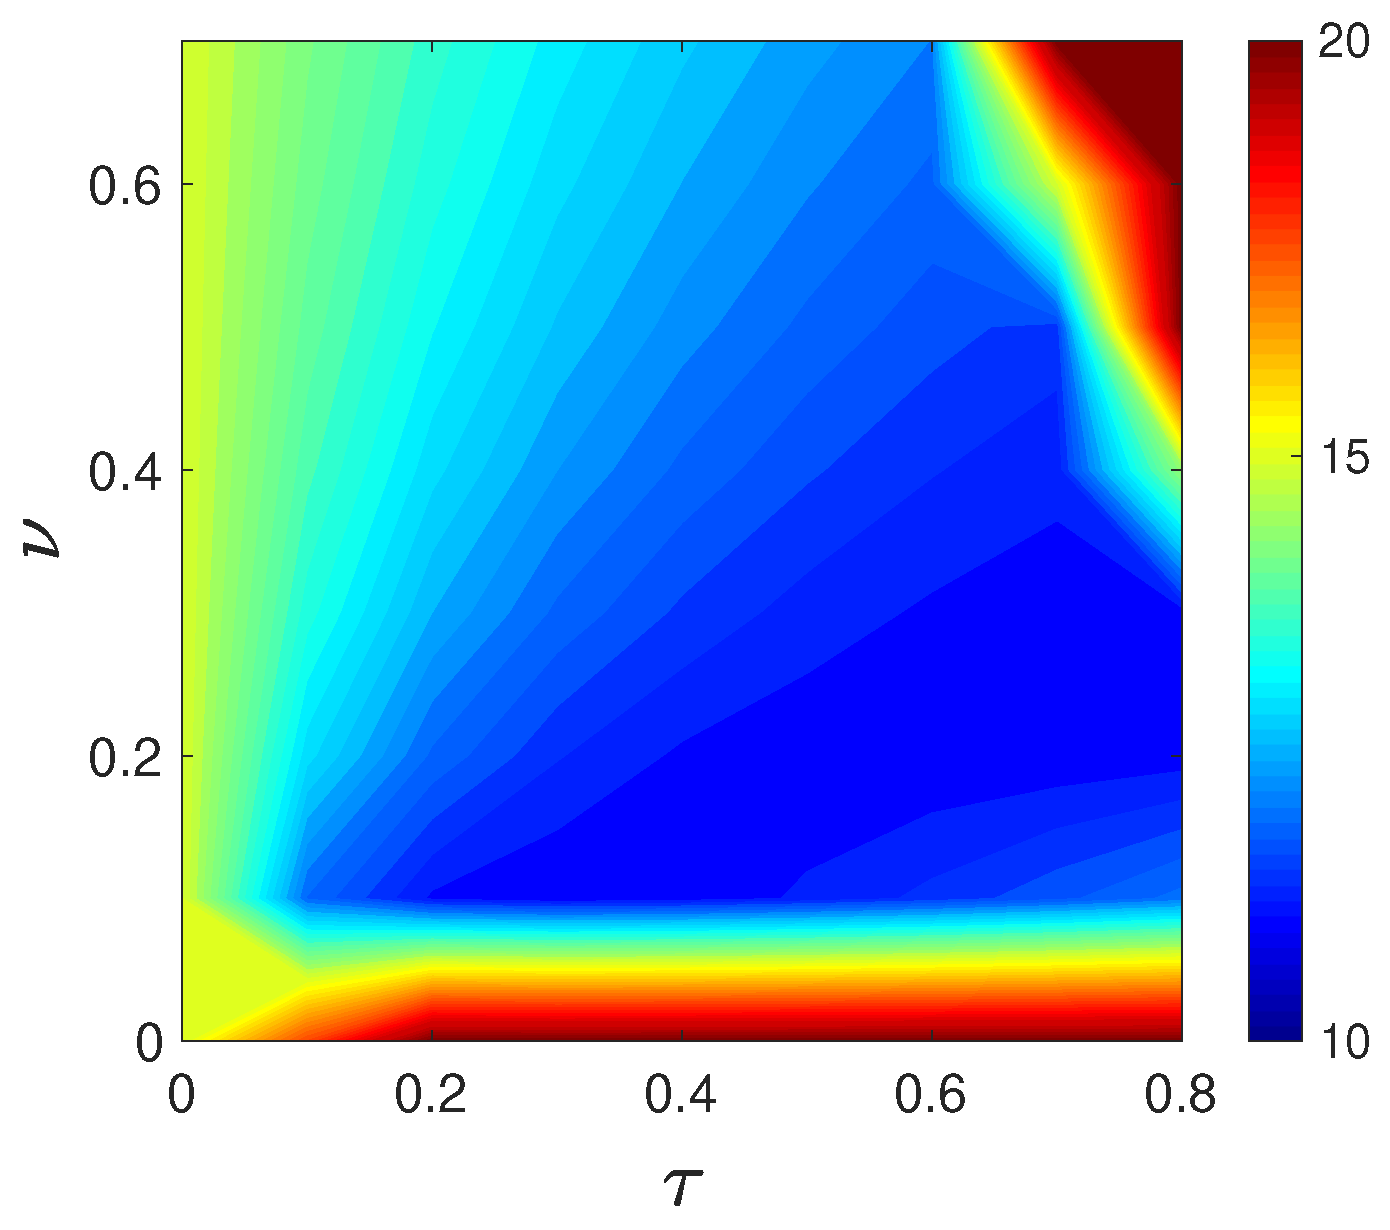
Contour maps of the logarithmic discrepancy measure for CDSA and CDEM are shown in Figure 6, based on a parameter grid where and were incremented by 0.1. While the discrepancy measure varies with parameter choice in both methods, the regions yielding optimal parameters differ between CDSA and CDEM. In addition, the results suggest that parameter tuning reduces the discrepancy more substantially in CDEM than in CDSA.
Figure 6.
Contour plots of the logarithmic discrepancy measure for reconstructions made using (a) CDSA and (b) CDEM, with 20 dB noisy projections.
To examine how the optimal parameter settings vary with noise level, we performed the same parameter grid experiment for CDEM with a higher signal quality. Figure 7 shows the contour map of obtained with 30 dB projection noise. Compared with the 20 dB case, the location of the optimal region in the parameter space is shifted, indicating that the most effective parameter values depend on the noise level.
Figure 7.
Contour plots of the logarithmic discrepancy measure for reconstructions made using CDEM with 30 dB noisy projections.
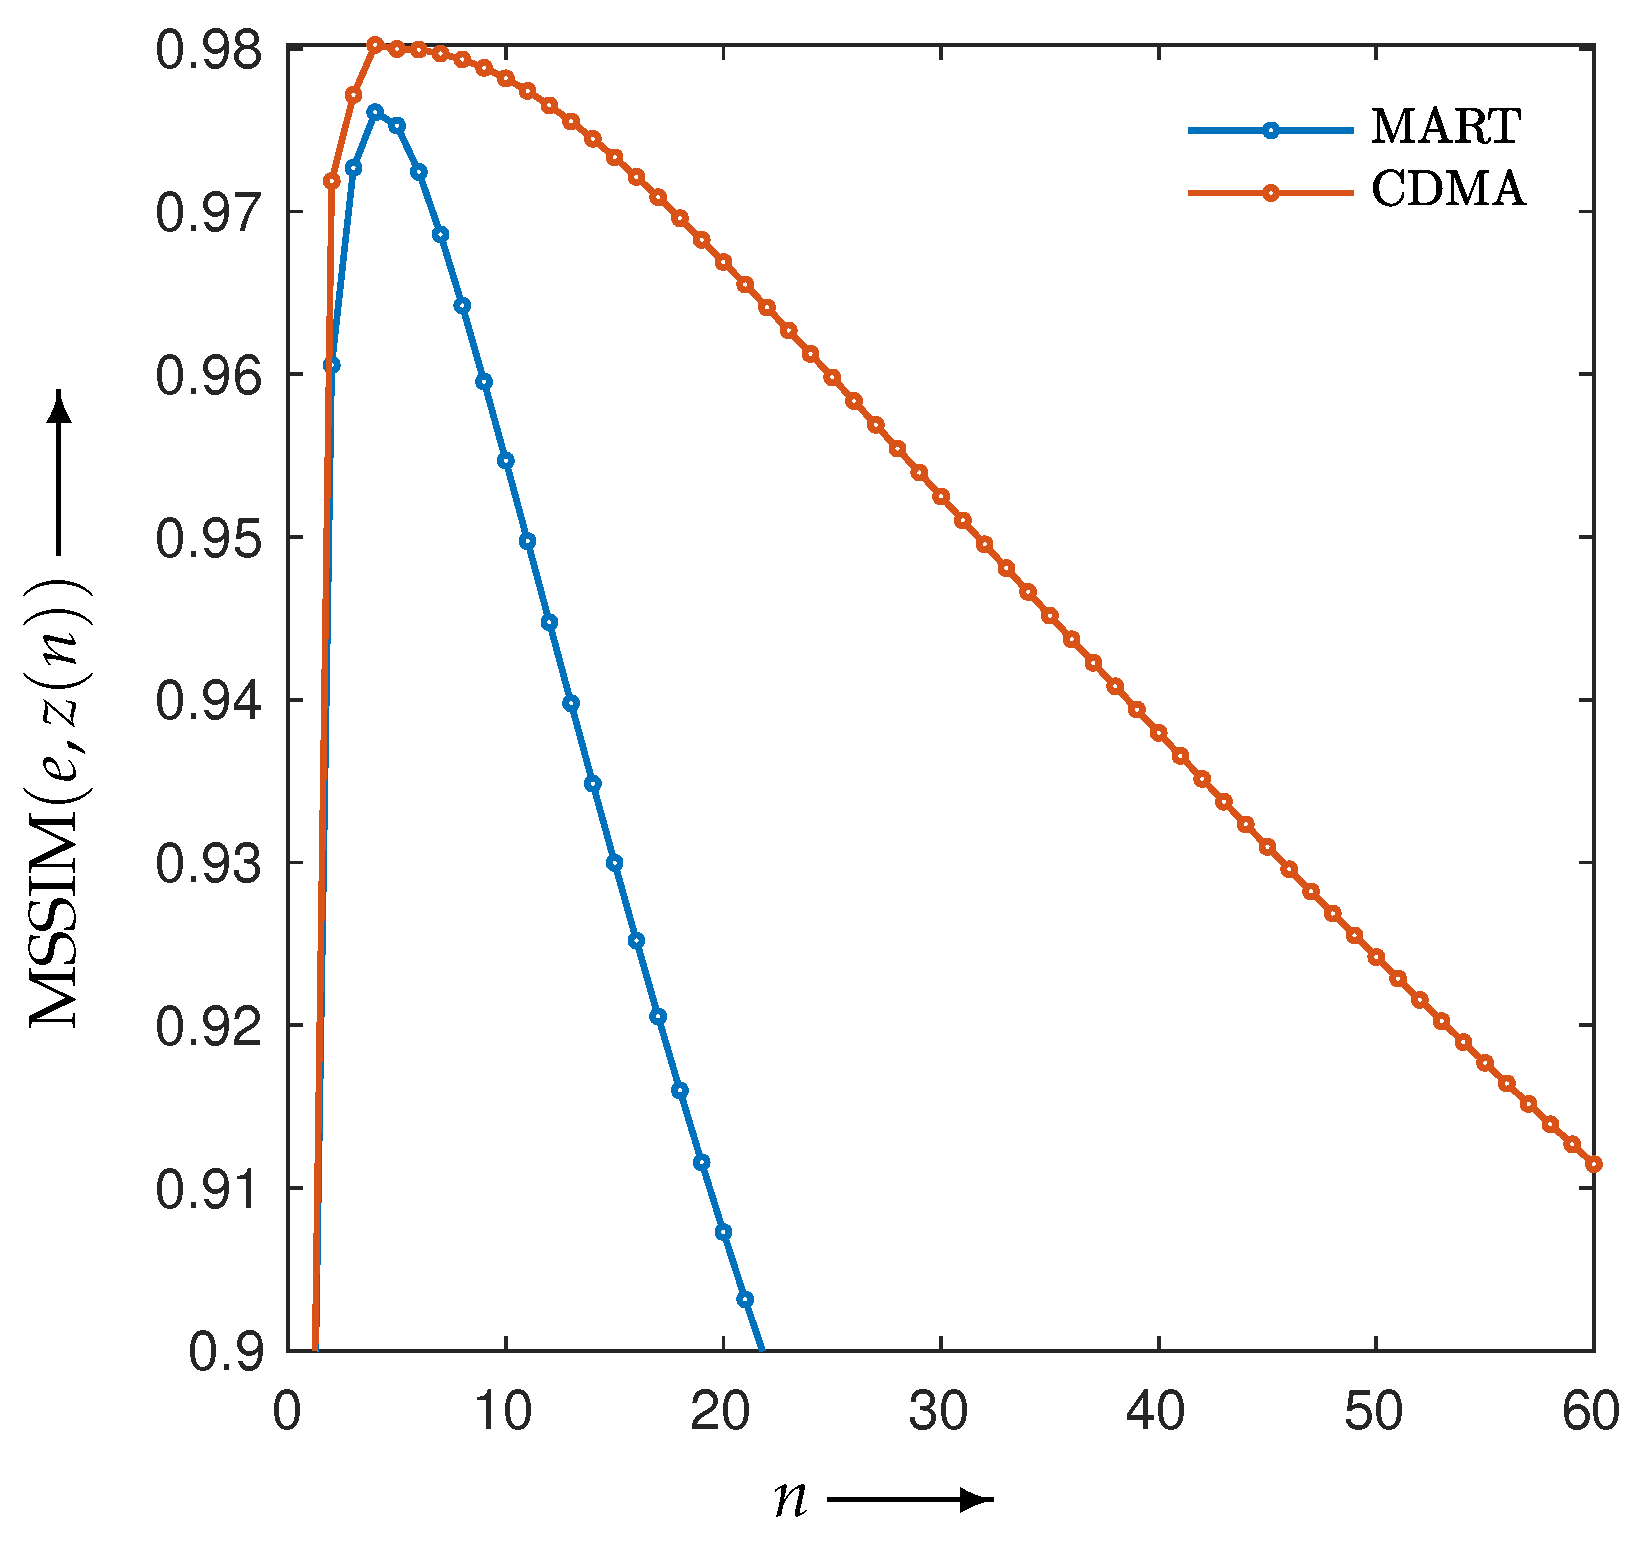
We also conducted reconstruction experiments using the nonlinear system, CDMA, which is based on MART. Figure 8 presents the evolution of MS-SSIM over the iterations. These results demonstrate that CDMA achieves higher image quality than MART does. Moreover, compared with the EM-type method CDEM, CDMA improves the SSIM evaluation measure more rapidly, reaching higher similarity values in fewer iterations. CDMA may thus be a useful alternative to CDEM that improves image quality quickly with fewer iterations. That is, while CDEM may achieve better results with more iterations, CDMA would be advantageous when faster convergence is preferred.
Figure 8.
MS-SSIM () as a function of iteration number n for image reconstruction made using CDMA with 20 dB noisy projections.
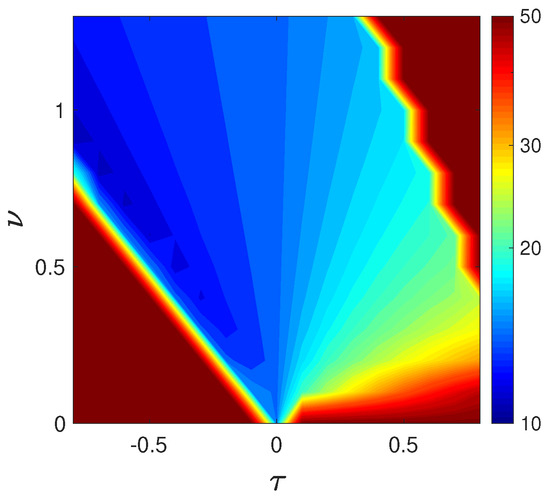
Figure 9 presents the contour map of the logarithmic discrepancy measure for CDSA under noise-free projections. To further explore the behavior in ideal conditions, we extended the parameter range to include negative values of . As anticipated from the theoretical analysis, the discrepancy measure increases significantly in regions where , reflecting instability of the equilibrium. Unlike in the noisy case shown in Figure 6a, it can be seen that, in the absence of noise, there exists a region with negative where the discrepancy measure attains its minimum.
Figure 9.
Contour plots of the logarithmic discrepancy measure for reconstructions made using CDSA with noise-free projections.
4. Discussion
The proposed coupled dynamical systems, consisting of one linear and two nonlinear variants, are designed to solve linear inverse problems and admit a well-defined equilibrium. Their stability has been rigorously analyzed using Lyapunov’s direct method by constructing explicit Lyapunov functions. Such an analysis is possible because the equilibrium of the proposed systems coincides with the true solution, in contrast to standard regularization approaches. This approach enables a clear and transparent analysis of the global behavior across the proposed systems.
In the case of the linear system, we additionally performed a spectral analysis by deriving the eigenvalues of the Jacobian matrix at equilibrium. Due to the linearity of the system, the local asymptotic stability implied by the spectral condition is directly translated to global asymptotic stability. Notably, the spectral condition reveals that stability can be achieved even when , depending on the value of and the structure of the system matrix. This highlights a key distinction: spectral analysis yields precise global stability conditions for the linear system, while the Lyapunov approach provides more conservative but broadly applicable guarantees, including for nonlinear systems.
To evaluate the practical performance of the proposed systems under realistic conditions, we conducted numerical experiments using synthetic projection data corrupted with additive Gaussian noise. While the proposed coupled dynamical systems are formulated as continuous-time differential equations, the numerical methods used in the implementation are based on discrete-time iterations derived via additive or multiplicative Euler discretization. As detailed in Section 3, reconstruction quality was assessed using both the Euclidean discrepancy and MS-SSIM. Among the tested methods, CDEM consistently outperformed both of the conventional algorithms (MLEM and SART) and our other proposal CDSA, achieving the smallest discrepancy and highest structural similarity to the ground truth, along with superior noise suppression and structural preservation. Visual inspection of reconstructed images and difference maps confirmed that CDEM yields cleaner results, while the intensity profile analysis showed that it more accurately reproduces the true values, especially in flat regions where noise suppression is essential.
Although CDEM required more computation time than MLEM because of the increased number of state variables, the improvement in reconstruction quality justifies this increase in computation time. Specifically, the number of state variables increased from in MLEM to in CDEM, resulting in approximately a 37% increase in computation time. As shown in Section 3, the Euclidean discrepancy of CDEM at iteration 60 was significantly smaller than the lowest value achieved by MLEM during its iterations. This indicates that increasing the number of MLEM iterations would not imply the same level of accuracy as CDEM. Therefore, the increase in computation time is not a major drawback when considering the performance gains.
These experimental results indicate that setting the parameter to a positive value not only guarantees stability as established by Lyapunov theory, but also plays a critical role in reducing the effects of noise. In particular, the parameter plane analyses shown in Figure 6 and Figure 7 reveal that reconstruction accuracy depends sensitively on the values of both and and that optimal performance under noisy conditions is typically achieved when is appropriately chosen.
In contrast, for the linear system with , the experimental results support the theoretical prediction that stability can still be maintained in regions where . However, since the coupled dynamical systems are intended as solvers for linear inverse problems involving measurement uncertainty, we regard the noise-free experiments to be a verification of theoretical properties rather than a basis for drawing practical algorithmic conclusions.
As described in Section 3, CDEM and CDMA demonstrate significant improvements over their classical counterparts; however, they exhibit distinct convergence behaviors. In particular, CDMA achieves higher image similarity at earlier iterations, making it well suited for applications where rapid reconstruction is required. On the other hand, CDEM consistently attains the highest structural similarity when sufficient iterations are allowed, offering superior performance in scenarios where reconstruction quality is prioritized over speed. These complementary characteristics suggest that CDEM and CDMA can be selectively applied depending on the specific demands of the imaging task.
5. Conclusions
We proposed a class of coupled dynamical systems, consisting of one linear and two nonlinear variants, as a framework for solving linear inverse problems. These systems share a common equilibrium, and we established their global asymptotic stability using Lyapunov’s direct method. For the linear system, we additionally performed a spectral analysis, deriving necessary and sufficient conditions for stability. Due to the system’s linearity, the local spectral conditions directly imply global stability and offer sharp theoretical insight into its behavior. Although the Lyapunov stability conditions are generally sufficient but not necessary in all cases, they apply uniformly to both linear and nonlinear cases and offer a consistent and interpretable framework for assessing global dynamics.
We further evaluated the practical performance of the proposed systems by discretizing them into iterative reconstruction algorithms and testing them under noisy conditions. Among the proposed nonlinear methods, the EM-type system CDEM demonstrated high reconstruction quality, while the MA-type system CDMA showed the ability to improve image quality with fewer iterations. These complementary characteristics suggest that the choice between CDEM and CDMA can be guided by the specific demands of the imaging task, such as balancing reconstruction accuracy and computational efficiency.
In our numerical experiments, we changed only the noise level and observed how it affected the performance of the proposed method. The results show that the choice of parameters and has a strong influence on the reconstruction quality. These parameters are likely affected not only by the level of projection noise but also by factors such as the ratio of the number of pixels to the number of projections and the structural complexity of the object being reconstructed. Developing efficient strategies for selecting these parameters remains an important topic for future research.
Author Contributions
Conceptualization, T.Y.; Data Curation, R.K. and T.Y.; Formal Analysis, R.K., O.M.A.A.-O. and T.Y.; Methodology, R.K., O.M.A.A.-O. and T.Y.; Software, R.K. and T.Y.; Supervision, T.Y.; Validation, R.K., O.M.A.A.-O. and T.Y.; Writing—Original Draft, R.K. and T.Y.; Writing—Review and Editing, R.K., O.M.A.A.-O. and T.Y. All authors have read and agreed to the published version of the manuscript.
Funding
This research was partially supported by JSPS KAKENHI, Grant Number 24K07507.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The original contributions presented in this study are included in the article material. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Tarantola, A. Inverse Problem Theory and Methods for Model Parameter Estimation; Society for Industrial and Applied Mathematics: Philadelphia, PA, USA, 2005. [Google Scholar]
- Hansen, P.C. Discrete Inverse Problems: Insight and Algorithms; Society for Industrial and Applied Mathematics: Philadelphia, PA, USA, 2010. [Google Scholar]
- Bertero, M.; Boccacci, P. Introduction to Inverse Problems in Imaging; Institute of Physics Publishing: Bristol, UK, 1998. [Google Scholar]
- Engl, H.W.; Hanke, M.; Neubauer, A. Regularization of Inverse Problems; Springer Science & Business Media: Berlin/Heidelberg, Germany, 1996; Volume 375. [Google Scholar]
- Aster, R.C.; Borchers, B.; Thurber, C.H. Parameter Estimation and Inverse Problems, 2nd ed.; Elsevier: Amsterdam, The Netherlands, 2013. [Google Scholar]
- Hansen, P.C. Rank-Deficient and Discrete Ill-Posed Problems: Numerical Aspects of Linear Inversion; Society for Industrial and Applied Mathematics: Philadelphia, PA, USA, 1998. [Google Scholar]
- Vogel, C.R. Computational Methods for Inverse Problems; Society for Industrial and Applied Mathematics: Philadelphia, PA, USA, 2002. [Google Scholar]
- Kaipio, J.; Somersalo, E. Statistical and Computational Inverse Problems; Springer: New York, NY, USA, 2005. [Google Scholar]
- Haber, E.; Ruthotto, L. Stable architectures for deep neural networks. Inverse Probl. 2017, 34, 014004. [Google Scholar] [CrossRef] [Scilit]
- Scherzer, O.; Grasmair, M.; Grossauer, H.; Haltmeier, M.; Lenzen, F. Variational Methods in Imaging; Springer: New York, NY, USA, 2009. [Google Scholar]
- Chen, R.T.Q.; Rubanova, Y.; Bettencourt, J.; Duvenaud, D.K. Neural Ordinary Differential Equations. In Proceedings of the Advances in Neural Information Processing Systems, Montréal, QC, Canada, 3–8 December 2018; Bengio, S., Wallach, H., Larochelle, H., Grauman, K., Cesa-Bianchi, N., Garnett, R., Eds.; Curran Associates, Inc.: Red Hook, NY, USA, 2018; Volume 31, pp. 6571–6583. [Google Scholar]
- Raissi, M.; Perdikaris, P.; Karniadakis, G.E. Physics-informed neural networks: A deep learning framework for solving forward and inverse problems involving nonlinear partial differential equations. J. Comput. Phys. 2019, 378, 686–707. [Google Scholar] [CrossRef] [Scilit]
- Simon, D. Optimal State Estimation: Kalman, H Infinity, and Nonlinear Approaches; John Wiley & Sons: Hoboken, NJ, USA, 2006. [Google Scholar]
- Dempster, A.P.; Laird, N.M.; Rubin, D.B. Maximum likelihood from incomplete data via the EM algorithm. J. R. Stat. Soc. Ser. B (Methodol.) 1977, 39, 1–22. [Google Scholar] [CrossRef] [Scilit]
- Shepp, L.A.; Vardi, Y. Maximum likelihood reconstruction for emission tomography. IEEE Trans. Med. Imaging 1982, 1, 113–122. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Byrne, C. Iterative optimization in inverse problems. Inverse Probl. 1993, 9, 597. [Google Scholar]
- Vishampayan, S.; Stamos, J.; Mayans, R.; Koral, K.; Clinthorne, N.; Rogers, W.L. Maximum likelihood image reconstruction for SPECT. J. Nuc. Med. (Abs. Book) 1985, 26, 20. [Google Scholar]
- Lyapunov, A.M. Stability of Motion; Academic Press: New York, NY, USA, 1966. [Google Scholar]
- Tateishi, K.; Yamaguchi, Y.; Abou Al-Ola, O.M.; Yoshinaga, T. Continuous Analog of Accelerated OS-EM Algorithm for Computed Tomography. Math. Probl. Eng. 2017, 2017, 1564123. [Google Scholar] [CrossRef] [Scilit]
- Gordon, R.; Bender, R.; Herman, G.T. Algebraic reconstruction techniques (ART) for three-dimensional electron microscopy and X-ray photography. J. Theor. Biol. 1970, 29, 471–481. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Badea, C.; Gordon, R. Experiments with the nonlinear and chaotic behaviour of the multiplicative algebraic reconstruction technique (MART) algorithm for computed tomography. Phys. Med. Biol. 2004, 49, 1455–1474. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Wang, Z.; Bovik, A.C.; Sheikh, H.R.; Simoncelli, E.P. Image quality assessment: From error visibility to structural similarity. IEEE Trans. Image Process. 2004, 13, 600–612. [Google Scholar] [CrossRef] [Scilit] [PubMed]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2025 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).