


Abstract
The rapid growth of electric vehicle (EV) charging demand requires accurate short-term load forecasts and dispatch strategies that can respond to changing microgrid operating conditions. This study proposes a hybrid framework that combines a VMD-CNN-ABiLSTM-IGCRA forecasting model with a state-triggered adaptive scheduling strategy. Variational Mode Decomposition extracts multi-scale components from volatile charging profiles; the CNN and attention-based bidirectional LSTM learn local and long-range temporal features; and the Improved Giant Cane Rat Algorithm regulates the iterative search step and tunes the principal model hyperparameters. The scheduling layer constructs a five-dimensional state vector from electricity price, renewable-energy volatility, predicted EV load, grid carbon pressure, and available battery capacity. Historical thresholds activate four candidate operating cases: carbon-priority, price-driven, fluctuation-stabilized, and economic–environmental balanced scheduling. When several cases are triggered, the best feasible candidate is selected according to the current dispatch objective under common equipment and power-balance constraints. Three confidential real-world charging datasets from Shenzhen, each containing 744 hourly observations over 31 days, are evaluated using a chronological 70% training and 30% testing split. The proposed forecasting model obtains RMSE values of 1.7719–5.1042, MAE values of 0.8963–3.7562, and R2 values of 85.67–95.09% across the three datasets. In the station-level dispatch simulations, the balanced Case 4 reduces total cost relative to Case 1 by 16.95%, 54.53%, and 31.99% for Charging Stations 1–3, respectively. These results support the operational value of linking load forecasting with transparent state-dependent mode selection.
1. Introduction
The rapid expansion of electric mobility is increasing the temporal variability and spatial concentration of electricity demand at public charging facilities. For renewable-rich microgrids, this trend creates a coupled operational problem: the charging load must be forecast with sufficient accuracy, while wind, photovoltaic, gas-turbine, battery, and grid resources must be coordinated under changing economic, environmental, and stability conditions. Adaptive energy management has already proved valuable in intelligent fuel-cell hybrid vehicle platoons, where hierarchical speed planning and energy management are coordinated under complex traffic conditions [1]. Uncertainty quantification is also receiving broad attention in safety-critical engineering, as illustrated by mixture probabilistic programming for rainfall-induced slope-failure analysis [2]. A theory-informed multivariate framework for urban traffic forecasting further shows that incorporating domain relationships can improve the trustworthiness of short-term predictions [3]. Travel-mode research in Dubai and Lahore confirms that mobility attitudes and behavioral preferences materially influence urban transport choices, which are among the upstream factors shaping charging demand [4]. Beyond the transport domain, a hybrid convolutional model for multi-station water-level prediction demonstrates the transferable value of spatial–temporal feature learning for volatile infrastructure time series [5]. These studies collectively indicate that credible EV charging management requires both data-driven prediction and an operational mechanism that can translate forecasts into transparent dispatch actions.
Recent EV-oriented studies have improved the representation of charging demand and flexibility. Cavus et al. developed a residual-normalized multi-task GRU to jointly forecast household net load and EV charging demand in an IoT-enabled microgrid [6]. Genov et al. compared tree-based and cluster-based methods for forecasting EV charging flexibility, with attention to prediction error and computational requirements [7]. Cao et al. proposed a feature-enhanced probabilistic forecasting method in which correlation-based prior information is used to reweight external features for station-level charging-demand prediction [8]. These contributions strengthen charging-demand modeling, but their principal emphasis remains on forecast construction or flexibility estimation rather than on an explicit state-dependent interface between forecast outputs and multi-energy microgrid dispatch. Hybrid decomposition and deep learning methods provide a practical route for handling the non-stationary and multi-scale characteristics of energy time series. Guler et al. combined VMD, LSTM, Transformer blocks, and Bayesian optimization for electricity-load forecasting, thereby integrating signal decomposition, temporal learning, and hyperparameter selection [9]. Liu et al. coupled RIME-optimized VMD with multi-head self-attention and LSTM for wind-speed forecasting [10]. Romero-Barrera et al. incorporated wake-effect modeling, VMD preprocessing, and deep learning architectures to improve short-term wind-power forecasting [11]. Zhang et al. developed an XGBoost wind-speed model with VMD-LSTM error correction, showing that decomposition and residual correction can be combined within a forecasting pipeline [12]. These studies support the use of decomposition, convolutional or recurrent feature extraction, attention, and optimization in a unified architecture; however, the additional modules also increase the need for systematic parameter tuning and careful validation. Accurate charging forecasts are most useful when they are embedded in a physically meaningful renewable-energy system. Jonasson et al. evaluated hybrid offshore wind, wave, and floating-solar systems and showed that resource complementarity and shared infrastructure can improve techno-economic performance under suitable conditions [13]. Dong et al. formulated a coupled wind-photovoltaic-storage capacity-planning and energy-management model under nonlinear and economic constraints [14]. Awad et al. optimized a grid-connected solar-wind-pumped-hydro system for electricity and desalination demand, demonstrating the role of storage-backed hybridization in maintaining a high renewable fraction and supply adequacy [15]. Chafiq et al. developed an application-specific performance-evaluation framework for photovoltaic systems coupled with battery storage, emphasizing that evaluation criteria should reflect the configuration and operational purpose of the installation [16]. Accordingly, a charging-station microgrid should not be assessed only by predictive accuracy; its operating strategy should also account for renewable variability, storage availability, grid exchange, economic cost, and environmental impact.
Research on integrated-energy and microgrid dispatch has increasingly considered coordination among generation, storage, demand response, and network resources. Ma et al. proposed a two-stage dispatching strategy for park-level integrated energy systems using a master–slave-cooperative hybrid game model [17]. Zhang et al. studied coordinated operation of multiple microgrids and a distribution network through multi-package leasing of shared energy storage [18]. Al-Rasheedi and Al-Khayat assessed wind-solar complementarity through residual-load-based metrics, including ramping behavior and capacity-credit-related indicators [19]. Zhang et al. constructed a two-stage low-carbon economic dispatch model for generation-load-storage resources while explicitly evaluating flexible supply–demand balance [20]. Shen et al. developed a two-stage robust economic dispatch model that considers uncertainty in wind, solar, and load together with carbon emissions predicted by a neural-network model [21]. Gao et al. proposed a digital-twin-based distributed model predictive control strategy for a multi-energy virtual power plant with multi-timescale coordination and dynamic carbon management [22]. Pan et al. formulated a multi-objective robust dispatch and cost-allocation model for microgrids sharing hybrid energy storage while considering flexible ramping capacity [23]. Yu et al. developed a low-carbon economic dispatch strategy based on the feasible region of cooperative interaction among wind power, energy storage, and a carbon-capture power plant [24]. Although these studies improve robustness, flexibility, or multi-objective coordination, many dispatch formulations still rely on a fixed operating objective, a predetermined weighting structure, or a specific uncertainty set, rather than selecting among interpretable operating priorities according to the current microgrid state. The components used in the present forecasting and scheduling framework are also supported by recent methodological developments. Li et al. combined multi-feature inputs, VMD, an artificial-intelligence forecasting network, and the Polar Lights Optimizer for short-term multi-step wind-speed prediction [25]. Dong et al. used a CNN-BiLSTM forecasting component within a feedforward wind-alignment control framework, illustrating how predicted information can directly support equipment regulation [26]. Lamani et al. compared LSTM and BiLSTM for energy-consumption forecasting and reported the value of bidirectional temporal learning in capturing sequence dependencies [27]. Duan et al. integrated BiGRU self-attention prediction with LQPSO-based multi-energy microgrid scheduling, providing a direct example of forecast–scheduling coupling [28]. These findings motivate a forecasting model that combines decomposition, local feature extraction, bidirectional sequence learning, attention-based weighting, and automated parameter tuning, while retaining a clear connection to the subsequent dispatch problem.
Metaheuristic optimization offers flexible tools for tuning high-dimensional nonlinear models, but algorithm selection and modification should be supported by transparent mechanisms rather than by naming novelty alone. Shaikh et al. reviewed recently developed metaheuristics and emphasized their classifications, applications, and continuing challenges in search and analysis [29]. Wu et al. introduced a complex-order Darwinian particle swarm optimization method as an extension of particle-swarm search dynamics [30]. Abir et al. proposed GTG-ACO, which uses a graph transformer to learn heuristic and initial pheromone information for combinatorial optimization [31]. Zhong and Liang developed an elite-based butterfly optimization algorithm and applied it to speckle-projection-related optimization [32]. This broader literature indicates that adaptive search mechanisms can improve exploration and exploitation, but their contribution should ultimately be evaluated through forecasting accuracy, convergence behavior, and operational usefulness.
To address these gaps, this paper proposes a forecasting-dispatch framework for EV-charging microgrids in which the principal contribution lies in the transparent integration of forecasting, adaptive hyperparameter tuning [33,34], and state-dependent dispatch rather than in claiming novelty for each individual component. The forecasting module combines VMD, CNN, attention-based BiLSTM, and an adaptively weighted GCRA variant that follows the core exploration-exploitation balancing logic of adaptive metaheuristics [35,36]. The scheduling module then maps a five-dimensional operating-state vector to four interpretable objective configurations and evaluates the activated candidates under a common set of physical constraints. This design provides an explicit interface between predicted charging demand and dispatch decisions while retaining traceable operating priorities.
Compared with deep reinforcement learning approaches, the proposed scheduling layer follows a different design philosophy. For example, Fathollahi et al. used a DDPG actor-critic architecture to learn infrastructure-design decisions for wireless-charging electric buses through repeated interaction with an optimization environment [37]. Such learning-based approaches can capture nonlinear decision policies and may provide rapid inference after training, but their performance depends on the training environment, reward formulation, and representativeness of encountered states. In contrast, the present framework uses explicit threshold rules and constrained candidate evaluation, which improves interpretability and reduces policy-training requirements, but provides less autonomous adaptation and weaker out-of-distribution generalization. The two approaches should therefore be viewed as complementary rather than directly interchangeable.
- (1)
- A hybrid VMD-CNN-ABiLSTM forecasting pipeline is integrated with IGCRA-based hyperparameter tuning for short-term EV charging load prediction. The contribution is the coordinated use of decomposition, local feature extraction, bidirectional temporal modeling, attention weighting, and adaptive parameter search within a single forecasting-dispatch workflow.
- (2)
- The conventional Giant Cane Rat Algorithm is modified by introducing an iteration-dependent adaptive weight into the position-update step. Relative to standard GCRA, the initialization, objective evaluation, and basic population-search structure are retained, while the adaptive factor regulates the magnitude of candidate-position updates. The present study evaluates this modification through the resulting forecasting performance and does not claim a universally superior convergence rate.
- (3)
- The main system-level contribution is a state-triggered adaptive scheduling mechanism that connects forecasting outputs with constrained microgrid dispatch. A five-dimensional state vector and historical thresholds activate four interpretable operating priorities, and a common candidate-evaluation procedure resolves simultaneous triggers and selects a feasible scalarized dispatch result.
- (4)
- The framework is examined using three real-world Shenzhen charging datasets and corresponding station-level dispatch simulations. Because each dataset covers only 31 days, the evaluation is intended as a case-study demonstration rather than evidence of seasonal or universal generalization.
2. System Operating Framework
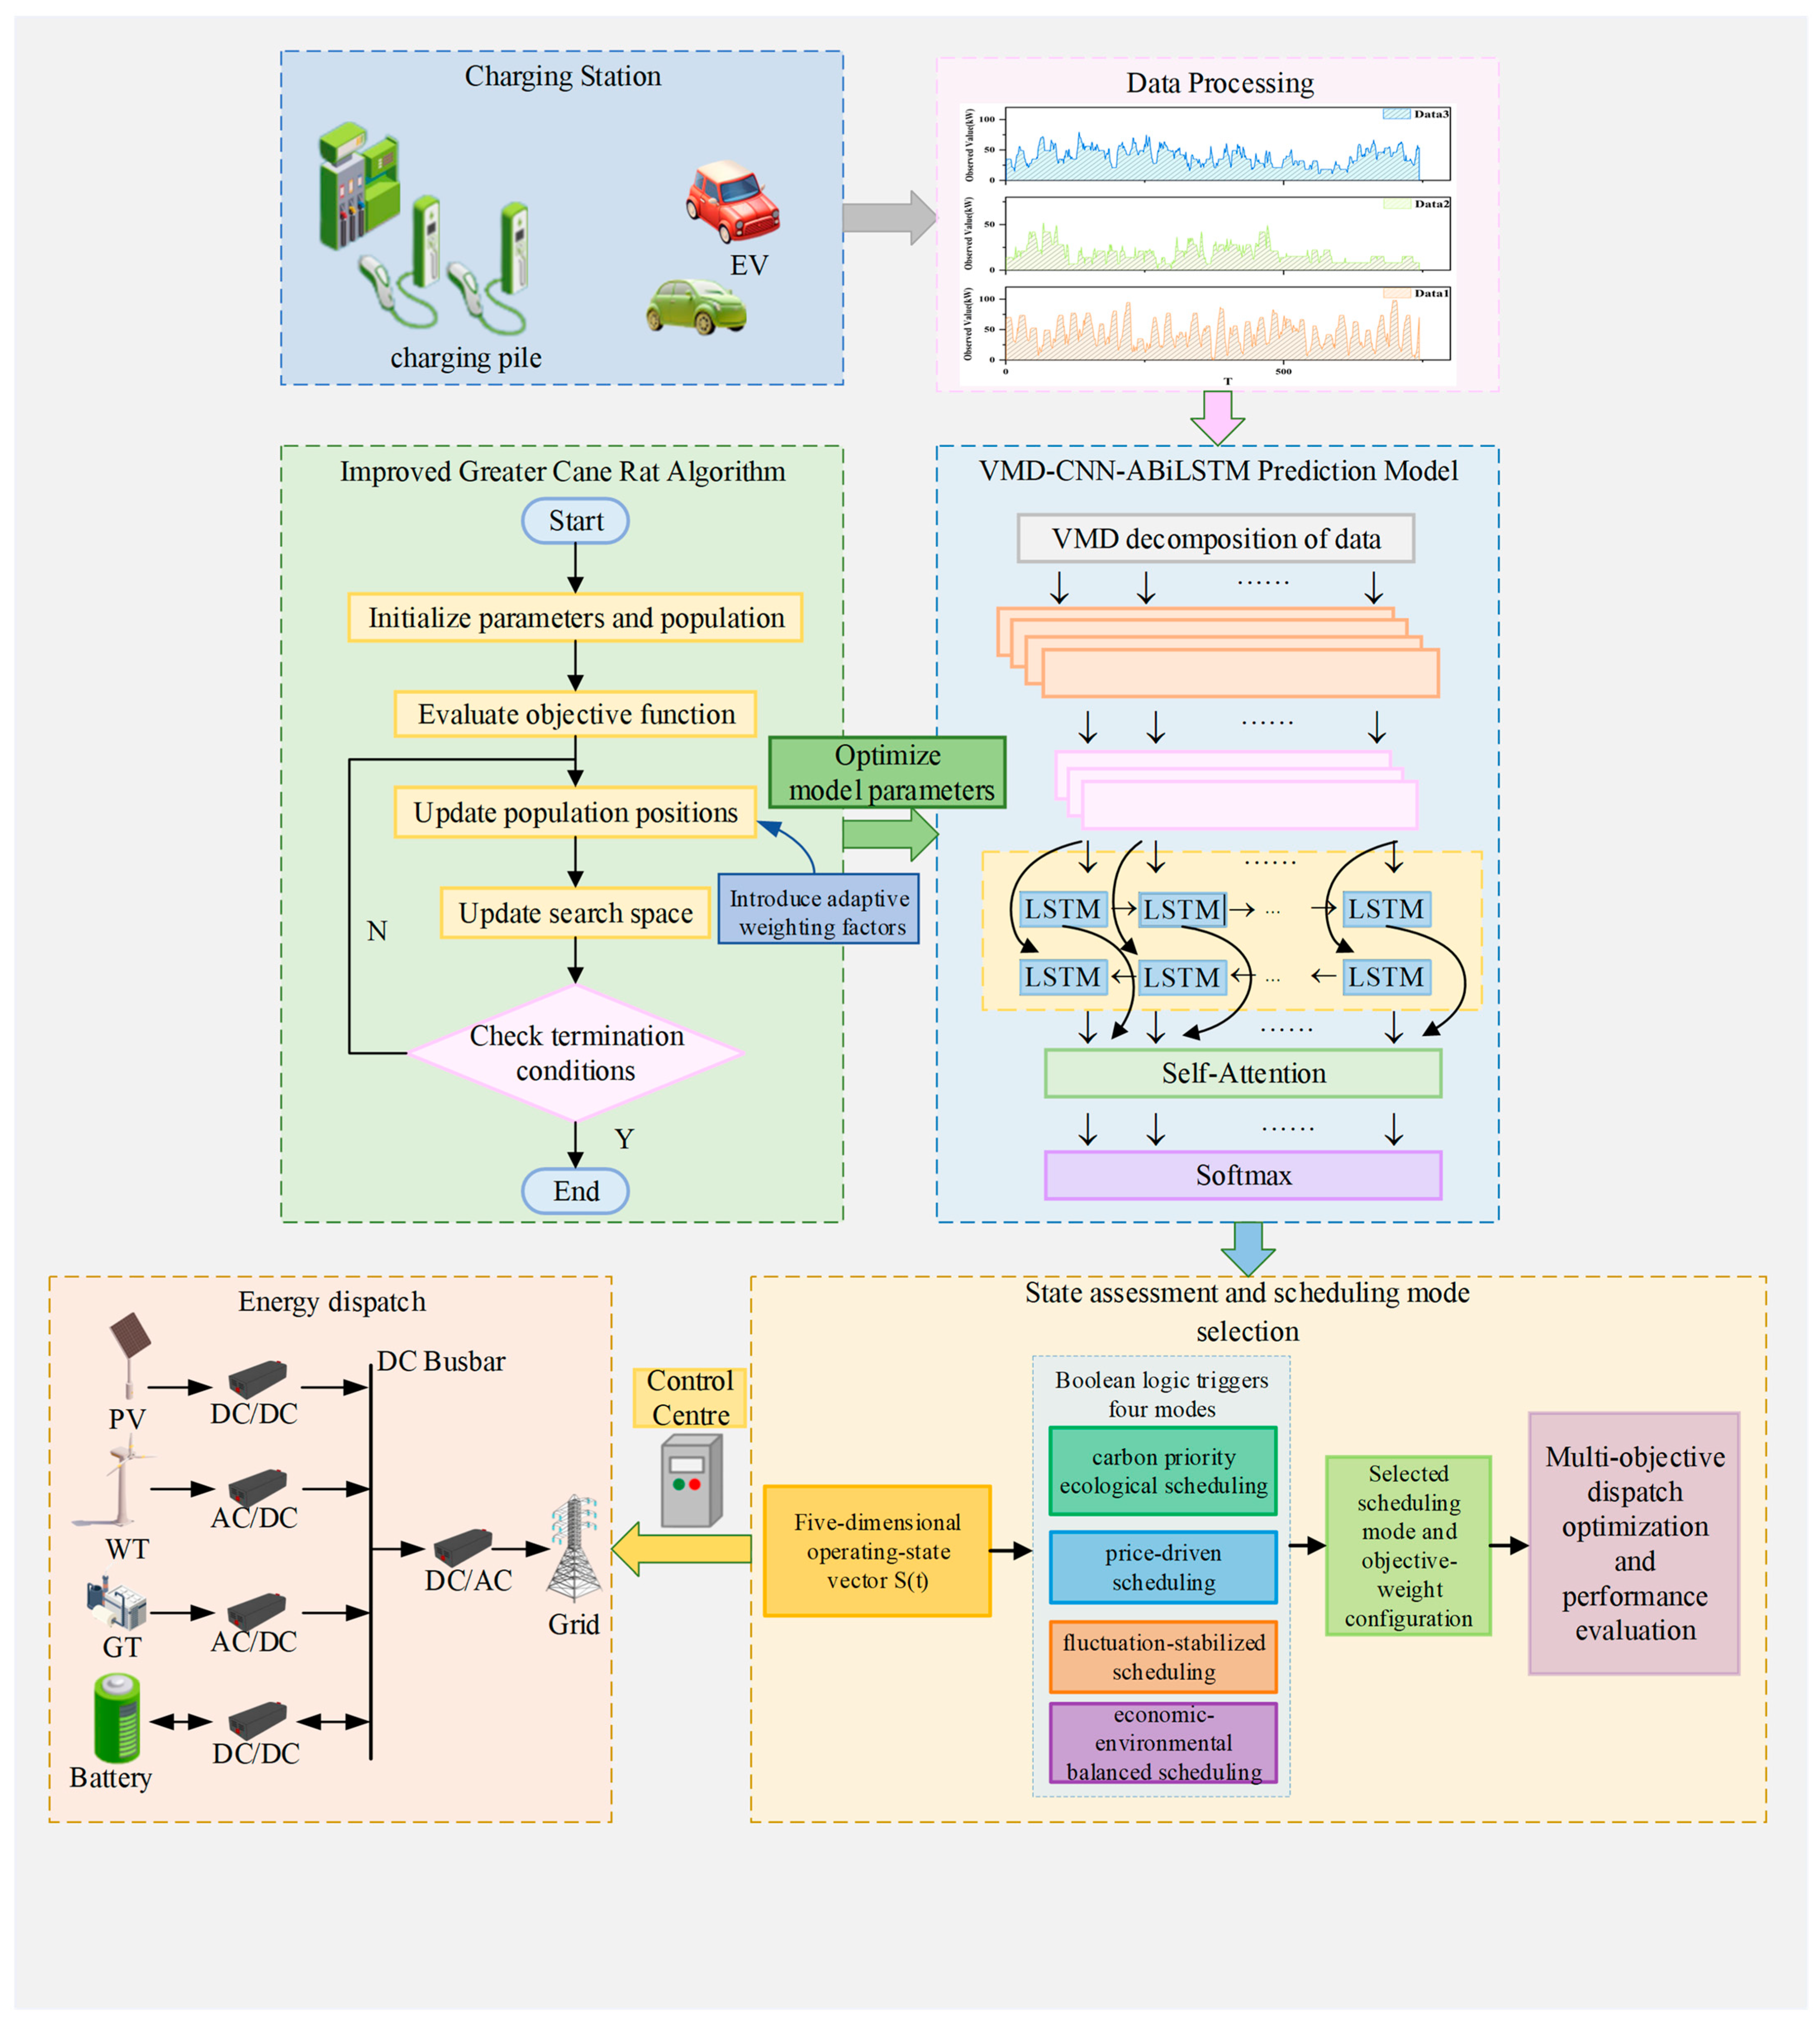
The proposed scheduling system comprises wind turbines (WT), photovoltaic generators (PV), gas turbine generators (GT), battery storage, and the utility grid. These energy resources operate in coordination to meet the system demand. When local generation is insufficient, electricity is purchased from the main grid; when surplus power is available, the excess electricity is exported to the grid to improve economic performance. The overall system architecture is illustrated in Figure 1.
Figure 1.
Overall framework of the proposed EV charging load forecasting and state-triggered adaptive microgrid dispatch method.
2.1. Wind Turbine Generator Model
The power output of a wind turbine depends primarily on the prevailing wind speed and can be expressed as follows:
where represents wind power generation output; signifies the nominal output of the wind turbine; indicates the current wind speed; corresponds to the cut-in threshold; identifies the cut-out limit; refers to the rated wind velocity; and , , , are wind speed parameters.
2.2. Photovoltaic Power Generation Unit Model
Photovoltaic power output is contingent upon incident solar irradiance and cell operating temperature. The calculation formula for photovoltaic module temperature () is as follows:
In the formula, the ambient-temperature term represents the operating air temperature, the wind-speed term represents the local wind condition used in the module-temperature correlation, and the irradiance term represents incident solar radiation. The previous description incorrectly referred to the wind-turbine rated power in this photovoltaic-temperature equation; this definition has been corrected.
The expression for photovoltaic power generation is:
In the formula, represents the photovoltaic power generation output; denotes the temperature coefficient; and indicates the reference operating ambient temperature.
2.3. Gas Turbine Generator Unit Model
A gas turbine generates electricity by combusting fuel gas to produce a high-temperature, high-pressure working fluid that expands through the turbine. Its electrical output is calculated as follows:
In the formula, represents the gas turbine power generation output; denotes the volume of methane consumed per unit time (unit: m3/h); indicates the calorific value of methane; stands for the working efficiency; and represents the operating time.
2.4. Battery Model
As an electrochemical storage unit, the battery supplies stored energy when renewable generation is insufficient to meet demand, thereby supporting reliable power delivery and system stability. Its charging and discharging behavior is modeled as follows:
In the equation: signifies the battery’s residual energy level at time t; stands for the battery power at time t, with positive values denoting charging and negative values indicating discharging; and and denote the round-trip efficiencies during energy uptake and release, respectively.
2.5. Electric Vehicle Load Prediction Model
2.5.1. Variational Mode Decomposition (VMD)
Variational Mode Decomposition (VMD) is an adaptive, fully non-recursive signal decomposition method designed to handle highly volatile and nonlinear time-series data. Its fundamental principle is to formulate and solve a constrained variational problem.
VMD decomposes the EV charging load waveform into a finite number of band-limited intrinsic mode functions through the following procedure:
VMD segregates the raw signal into k mode functions , as mathematically expressed below:
where represents the modal component; denotes the instantaneous amplitude; is the phase function; k indicates the number of modal components; and t stands for the time variable.
The VMD procedure unfolds in two sequential phases: the construction of the variational problem and its solution.
Construction of the variational problem:
Invoke the Hilbert transform on every extracted mode to construct the corresponding analytic signal and thereby generate its one-sided spectrum:
where represents the impulse function and denotes the convolution operator.
The exponential term serves to shift the spectrum of every mode to its designated baseband frequency
where denotes the center frequency.
The bandwidth of each modal component is estimated by solving the norm of the signal gradient , and the constrained variational problem is formulated as follows:
where denotes the set of all modal components, represents the set of all center frequencies, and corresponds to the original signal.
Construction of the variational problem:
To convert the constrained variational formulation into an unconstrained one, a quadratic penalty term and a Lagrange multiplier are introduced, yielding the following augmented Lagrangian:
where represents the Lagrangian multiplier and denotes the quadratic penalty coefficient.
2.5.2. Convolutional Neural Networks (CNNs)
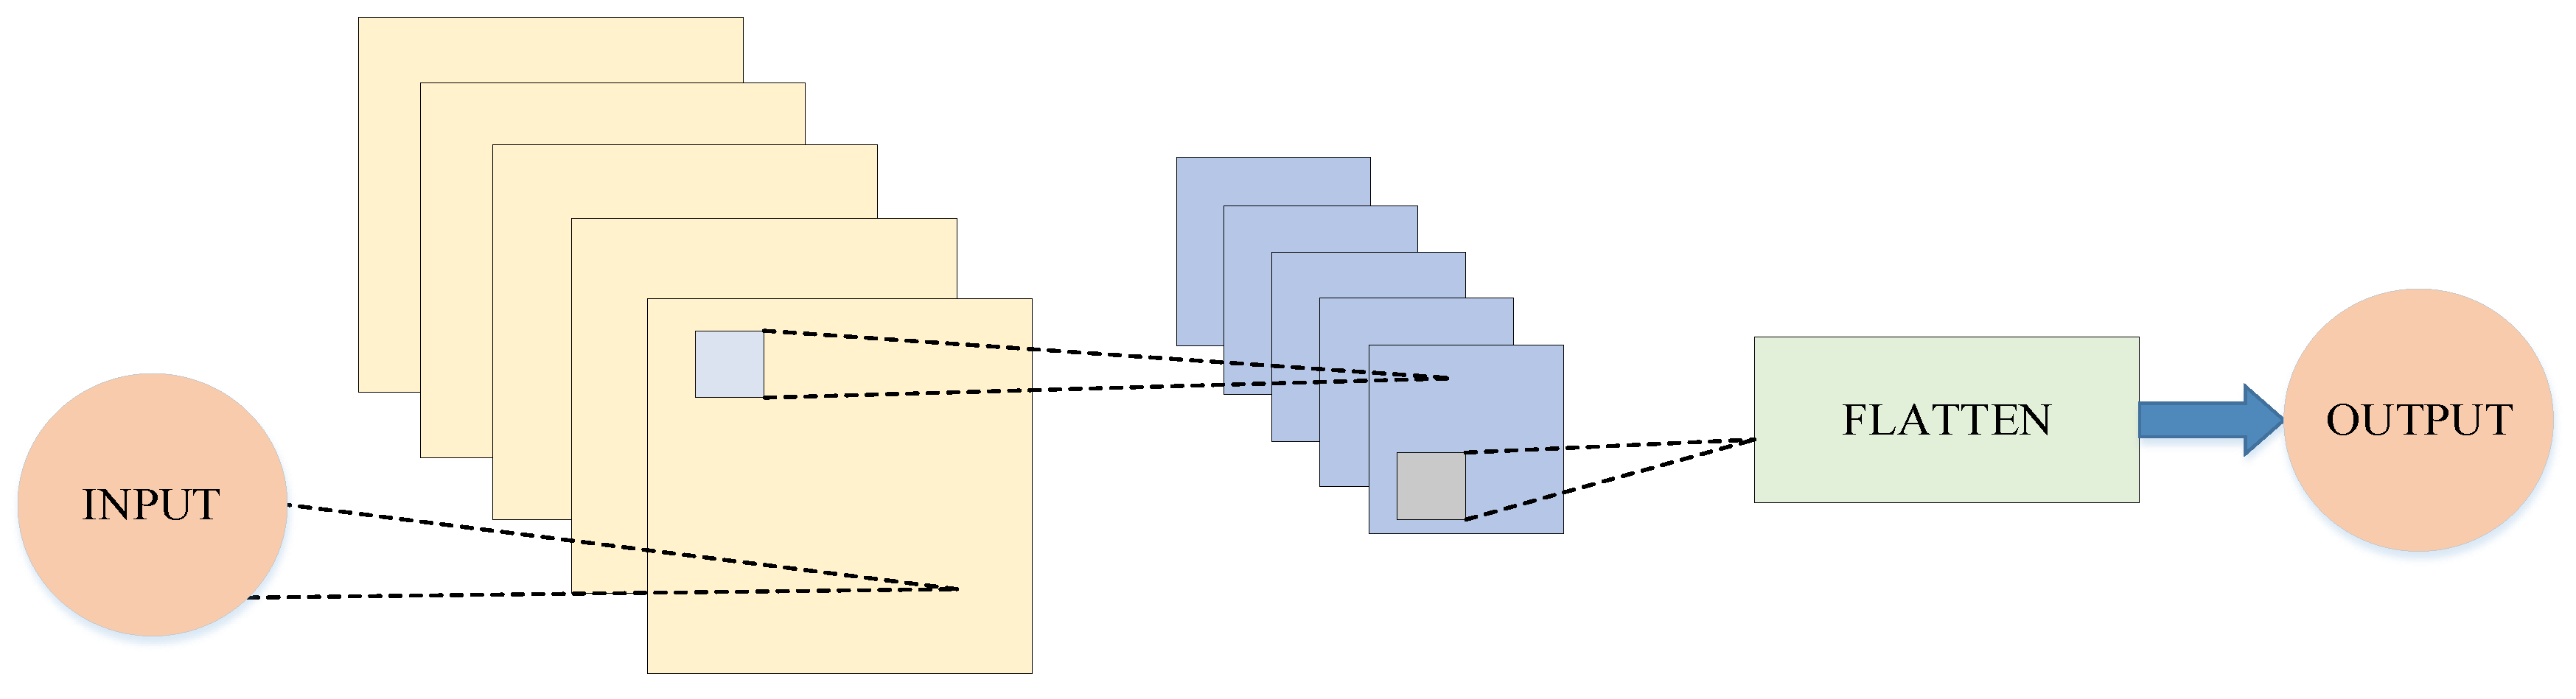
Convolutional Neural Networks (CNNs) can be trained in either supervised or unsupervised settings and are effective at extracting task-relevant patterns and discriminative features from complex data [26]. As illustrated in Figure 2, a standard CNN typically comprises an input layer, one or more convolutional and pooling layers, fully connected layers, and an output layer. The convolutional layer is the principal feature-extraction component, applying weighted local operations to the input as follows:
where represents the extracted features; and denote the weights and biases of the I-th convolutional layer, respectively; * indicates the convolution operation; and is the activation function, typically chosen as the Rectified Linear Unit (ReLU).
Figure 2.
CNN structure diagram.
2.5.3. Bidirectional Long Short-Term Memory (BiLSTM)
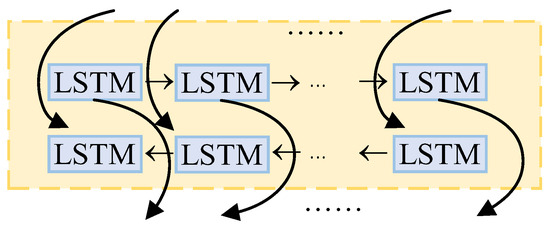
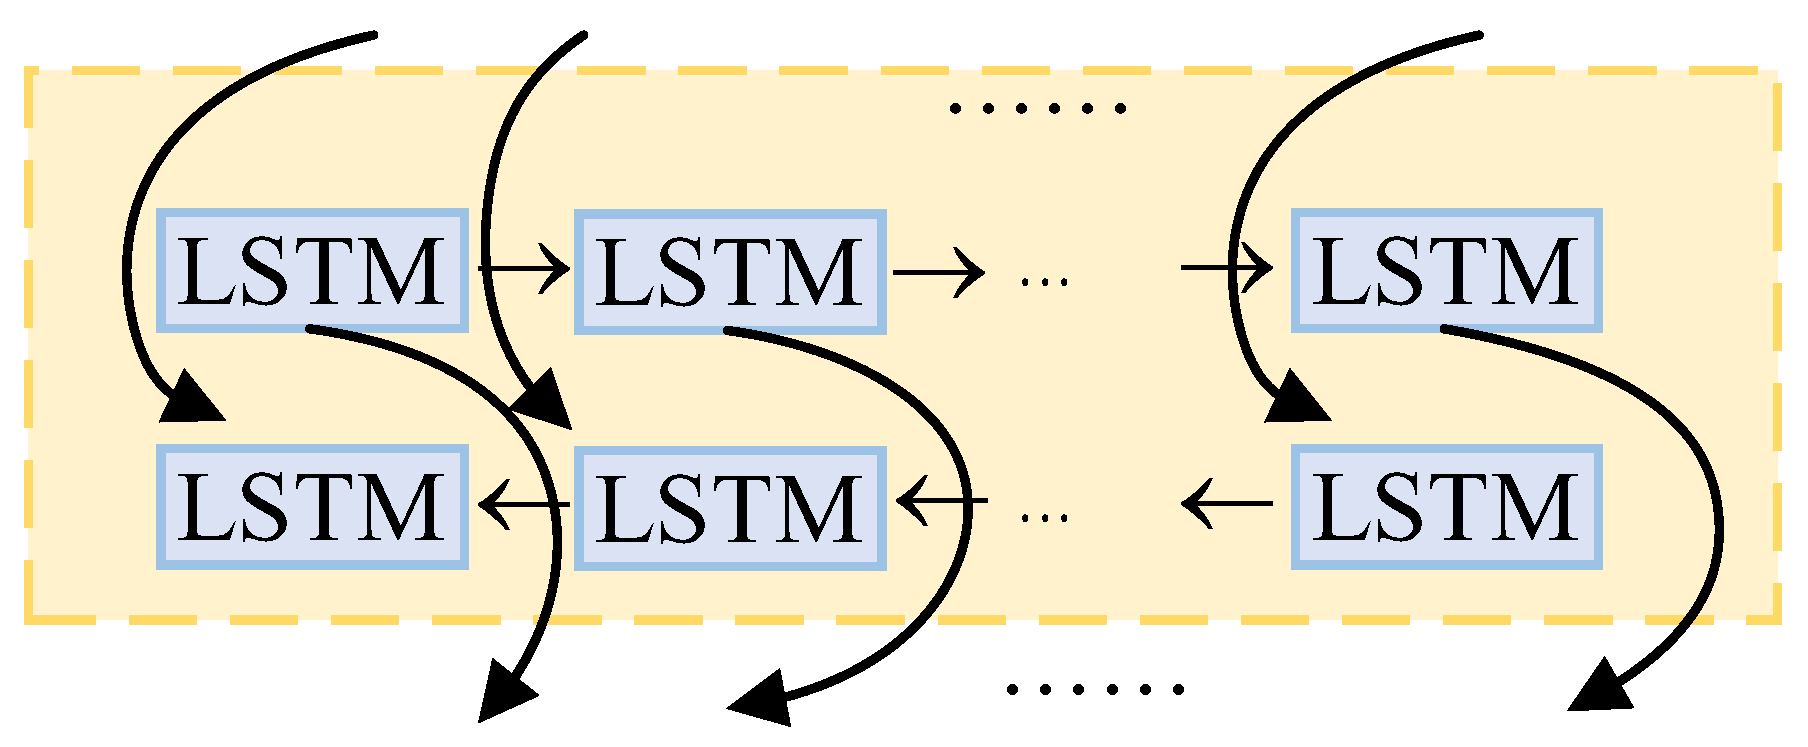
Long Short-Term Memory (LSTM) networks are recurrent architectures designed to mitigate vanishing-gradient problems and are widely used for sequence forecasting. In this study, a Bidirectional LSTM (BiLSTM), shown in Figure 3, combines forward and backward recurrent processing to capture both preceding and subsequent contextual information within the input sequence. Its computations are formulated as follows:
where denotes the EV-charging-load sequence emitted by the forward LSTM; signifies the present-step EV-charging-load vector; is the forward-LSTM output from the preceding time slice; represents the EV-charging-load sequence delivered by the backward LSTM; corresponds to the backward-LSTM output of the prior node; constitutes the ultimate EV-charging-load forecast; represents the forward weight matrix; denotes the backward weight matrix; and is the bias term for linear relationships.
Figure 3.
BiLSTM structure diagram.
2.5.4. Attention Mechanism (Attention)
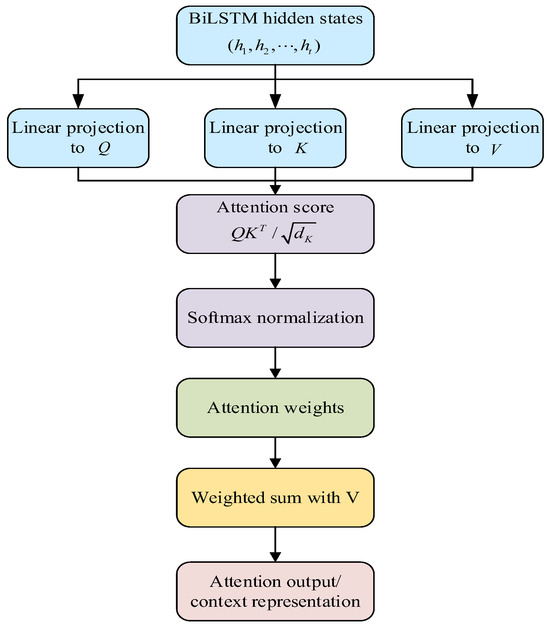
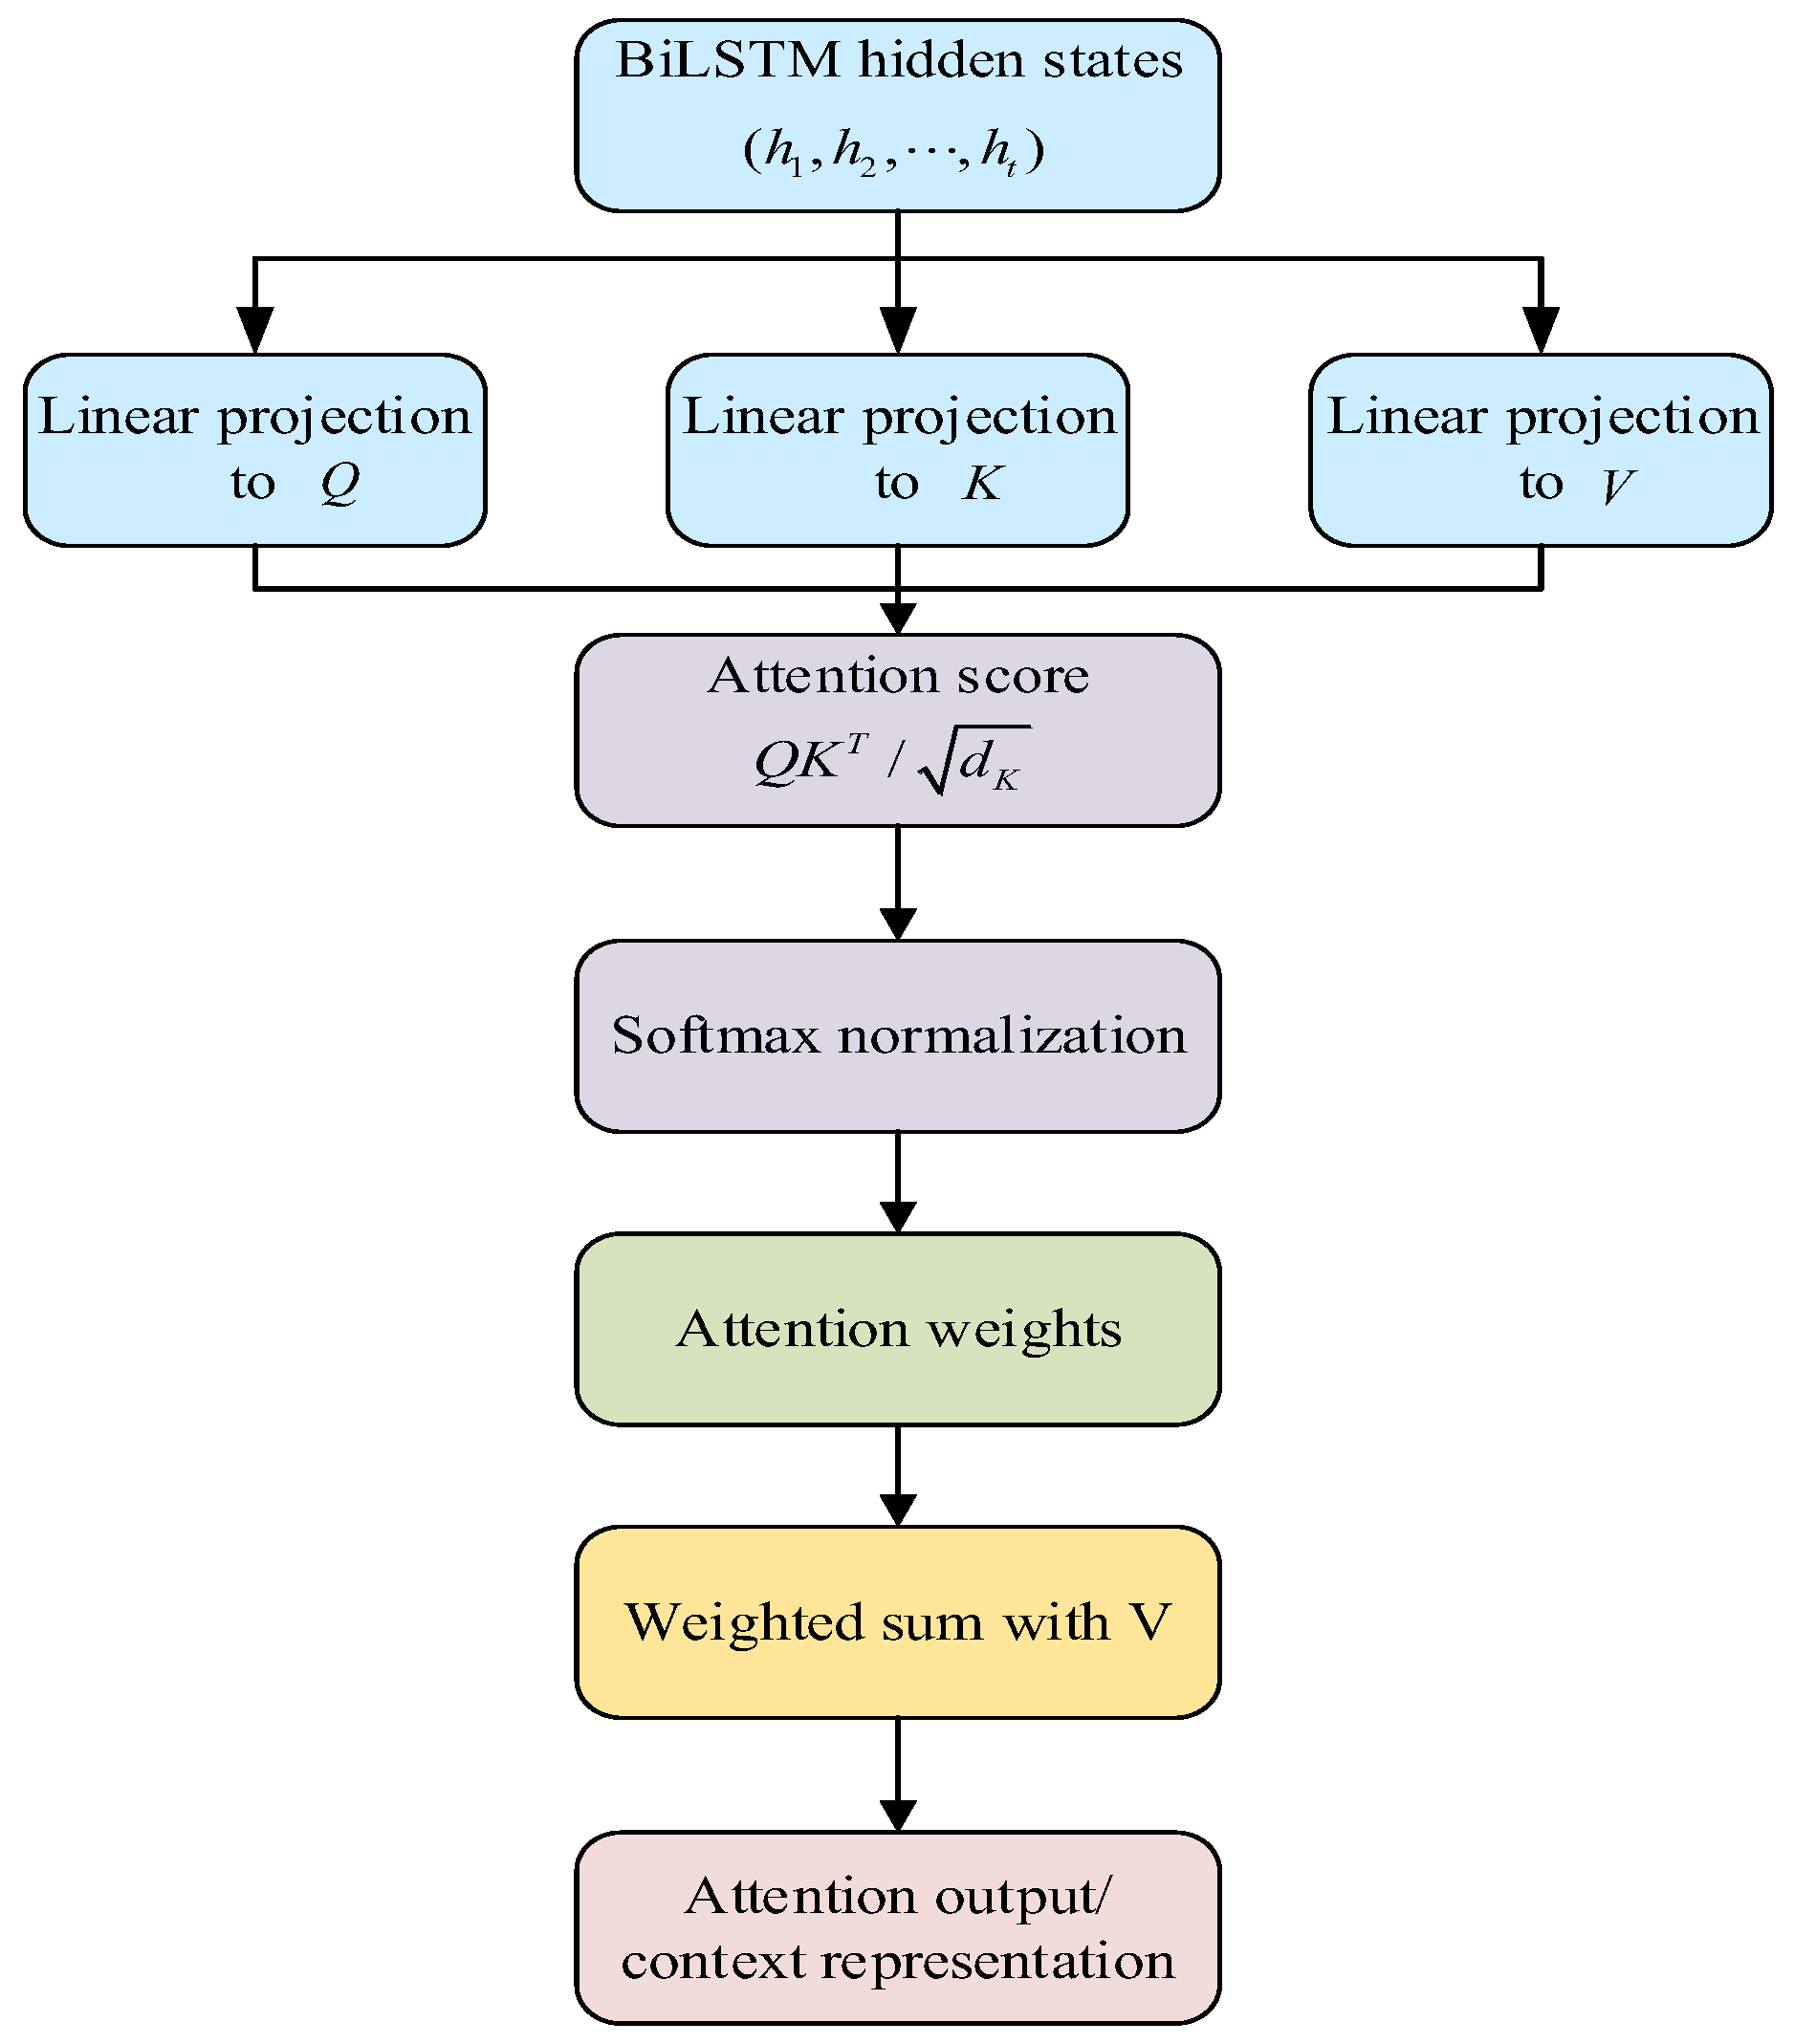
Although BiLSTM is effective at modeling long-range temporal dependencies, it may assign insufficient weight to critical time steps. To address this limitation, a self-attention mechanism is incorporated to identify and emphasize the most informative features. By adaptively reweighting the input sequence, the attention module improves predictive accuracy and generalization. Its structure is illustrated in Figure 4.
Figure 4.
Self-attention mechanism used in the forecasting model.
The formula for the attention mechanism is as follows:
where designates the attention operator; signifies the projection vector derived from each element of the input series; is the activation function; and indicates the dimensionality of the input sequence.
2.5.5. Improved Greater Cane Rat Algorithm (IGCRA)
The Giant Cane Rat Algorithm (GCRA) is a population-based metaheuristic inspired by the route-planning and foraging behavior of greater cane rats. In the present study, GCRA is selected as the base optimizer because of its relatively simple position-update structure, limited number of algorithm-specific control parameters, and straightforward integration with repeated neural-network hyperparameter evaluations. These characteristics reduce the implementation burden when each candidate solution requires training and validating the forecasting model. Therefore, the selection of GCRA is motivated by its structural simplicity and compatibility with the proposed forecasting framework, rather than by an assumption that it is universally superior to other evolutionary algorithms.
L-SHADE is a well-established adaptive differential evolution variant that combines success-history-based parameter adaptation with linear population-size reduction. L-SHADE and its variants constitute strong adaptive differential-evolution benchmarks, although their relative performance depends on problem dimensionality, landscape characteristics, and computational budget [33]. A rigorous comparison between IGCRA and L-SHADE would require identical decision variables, search bounds, population initialization, maximum numbers of function evaluations, stopping criteria, and repeated independent runs. The present study was designed primarily to examine whether the proposed adaptive modification improves the original GCRA within the VMD-CNN-ABiLSTM hyperparameter-tuning framework. Therefore, no claim is made that IGCRA is superior to L-SHADE or other state-of-the-art adaptive differential evolution variants. An equal-budget comparison with L-SHADE is regarded as an important extension of the present methodology. The main update equations are given as follows:
(1) The initial population and parameters are initialized. The starting positions of giant cane rats in the search space are randomly assigned, with the population matrix defined as follows:
where represents the giant cane rat population; indicates the j-th decision variable of the i-th cane rat’s candidate solution; n indicates the total number of population members; and d is the number of decision variables.
(2) The randomly generated positions of the giant cane rats are evaluated by substituting them into the objective function. Every giant cane rat encodes one feasible point in the solution space.
(3) The population members are updated by determining new positions in the search space based on the dominant male rat’s location, thereby optimizing the model parameters. The position update formula is as follows:
In the equation, denotes the new position of the i-th giant cane rat, represents its value in the j-th dimension; indicates the current position value of the giant cane rat; stands for the dominant male’s position; refers to the randomly selected female’s position; corresponds to the latest objective function value; signifies the current objective function value; encodes the alpha-male’s fitness; is a boundary-compliant random coordinate; models the attractiveness of rich forage patches; counts the elapsed iterations; gives the maximum search generations; represents the maximum iteration count; simulates the coefficient of diminishing food sources; governs the propensity to relocate toward remaining abundant zones; and is a random number between [1,4].
(4) The search space is updated by exploring food-abundant regions based on female rat positions, thereby optimizing the model parameters. The positional refresh rule is expressed as:
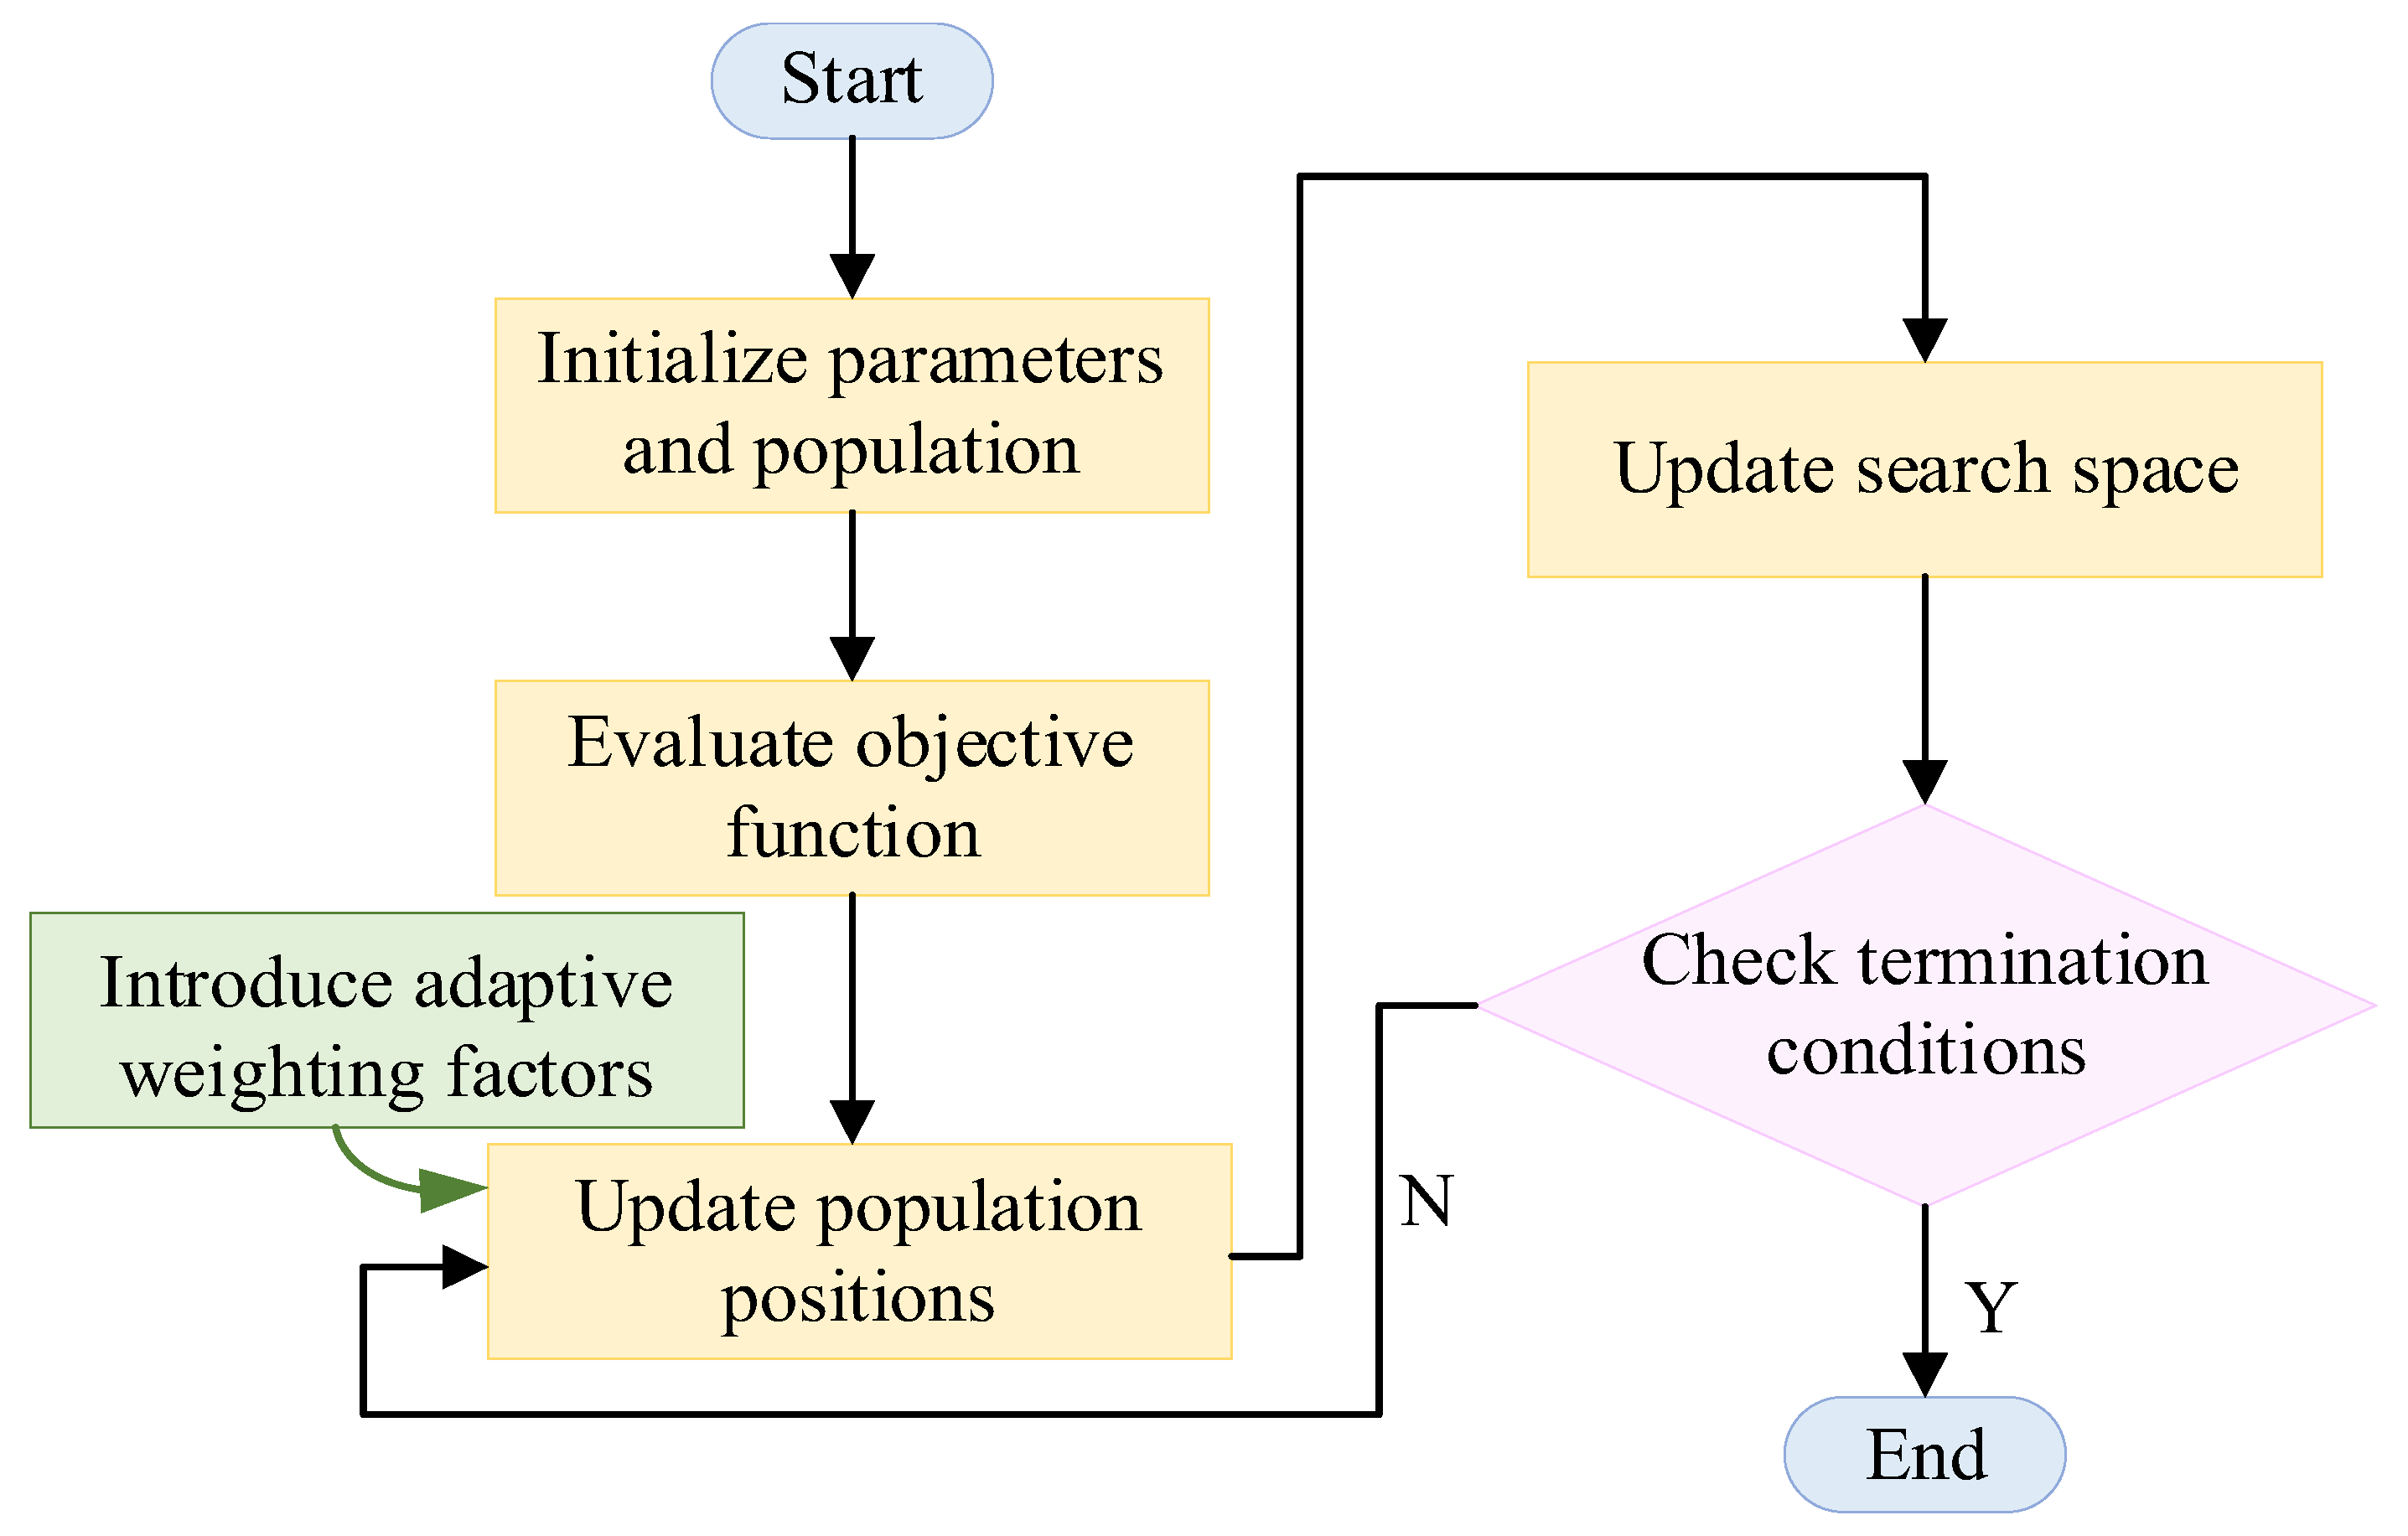
To strengthen solution refinement during the later iterations, an adaptive weight factor is introduced into the position-update rule to regulate the step size of newly generated candidate solutions. This paper improves Equation (4) by introducing an adaptive weight factor to modify the position of newly generated particles. The calculation formula is as follows:
The Improved Giant Cane Rat Algorithm (IGCRA) adaptively adjusts its search step according to the current population state and convergence behavior. The adaptive weight changes the magnitude of the position-update step according to the iterative state. Relatively larger update steps during the earlier iterations are intended to maintain broader search behavior, whereas progressively reduced steps during the later iterations are intended to support more concentrated refinement around promising candidate solutions. The proposed mechanism should therefore be interpreted as an iteration-dependent search-step regulation strategy rather than as direct evidence that an optimal exploration–exploitation balance has been achieved. The overall procedure is illustrated in Figure 5.
Figure 5.
Flowchart of IGCRA.
Mathematically, the distinction between GCRA and IGCRA in the present implementation is confined to the adaptive weighting of the candidate-position update. The remaining population initialization, fitness evaluation, dominant/female position references, boundary handling, and termination structure follow the base GCRA procedure. Accordingly, the adaptive factor should be interpreted as an iteration-dependent step-regulation mechanism, not as direct proof of an optimal exploration–exploitation balance or universally faster convergence.
In evolutionary algorithms, exploration refers to searching new regions of the solution space, whereas exploitation refers to refining solutions around promising regions [34]. Recent SHADE-based studies have combined offspring success rates with population-diversity information to characterize the transition between exploration and exploitation [35]. However, diversity-based indicators remain indirect and cannot determine whether population movements represent effective search. Attraction-basin-based measures provide a more direct assessment and can distinguish successful, failed, and deceptive exploration, as well as successful and unsuccessful exploitation [36]. Because complete population trajectories were not recorded in this study, we do not quantitatively claim an optimal exploration–exploitation balance. Instead, the adaptive factor is interpreted as a mechanism for regulating the search step during the iterative process.
2.5.6. The VMD-CNN-ABiLSTM-IGCRA Prediction Model
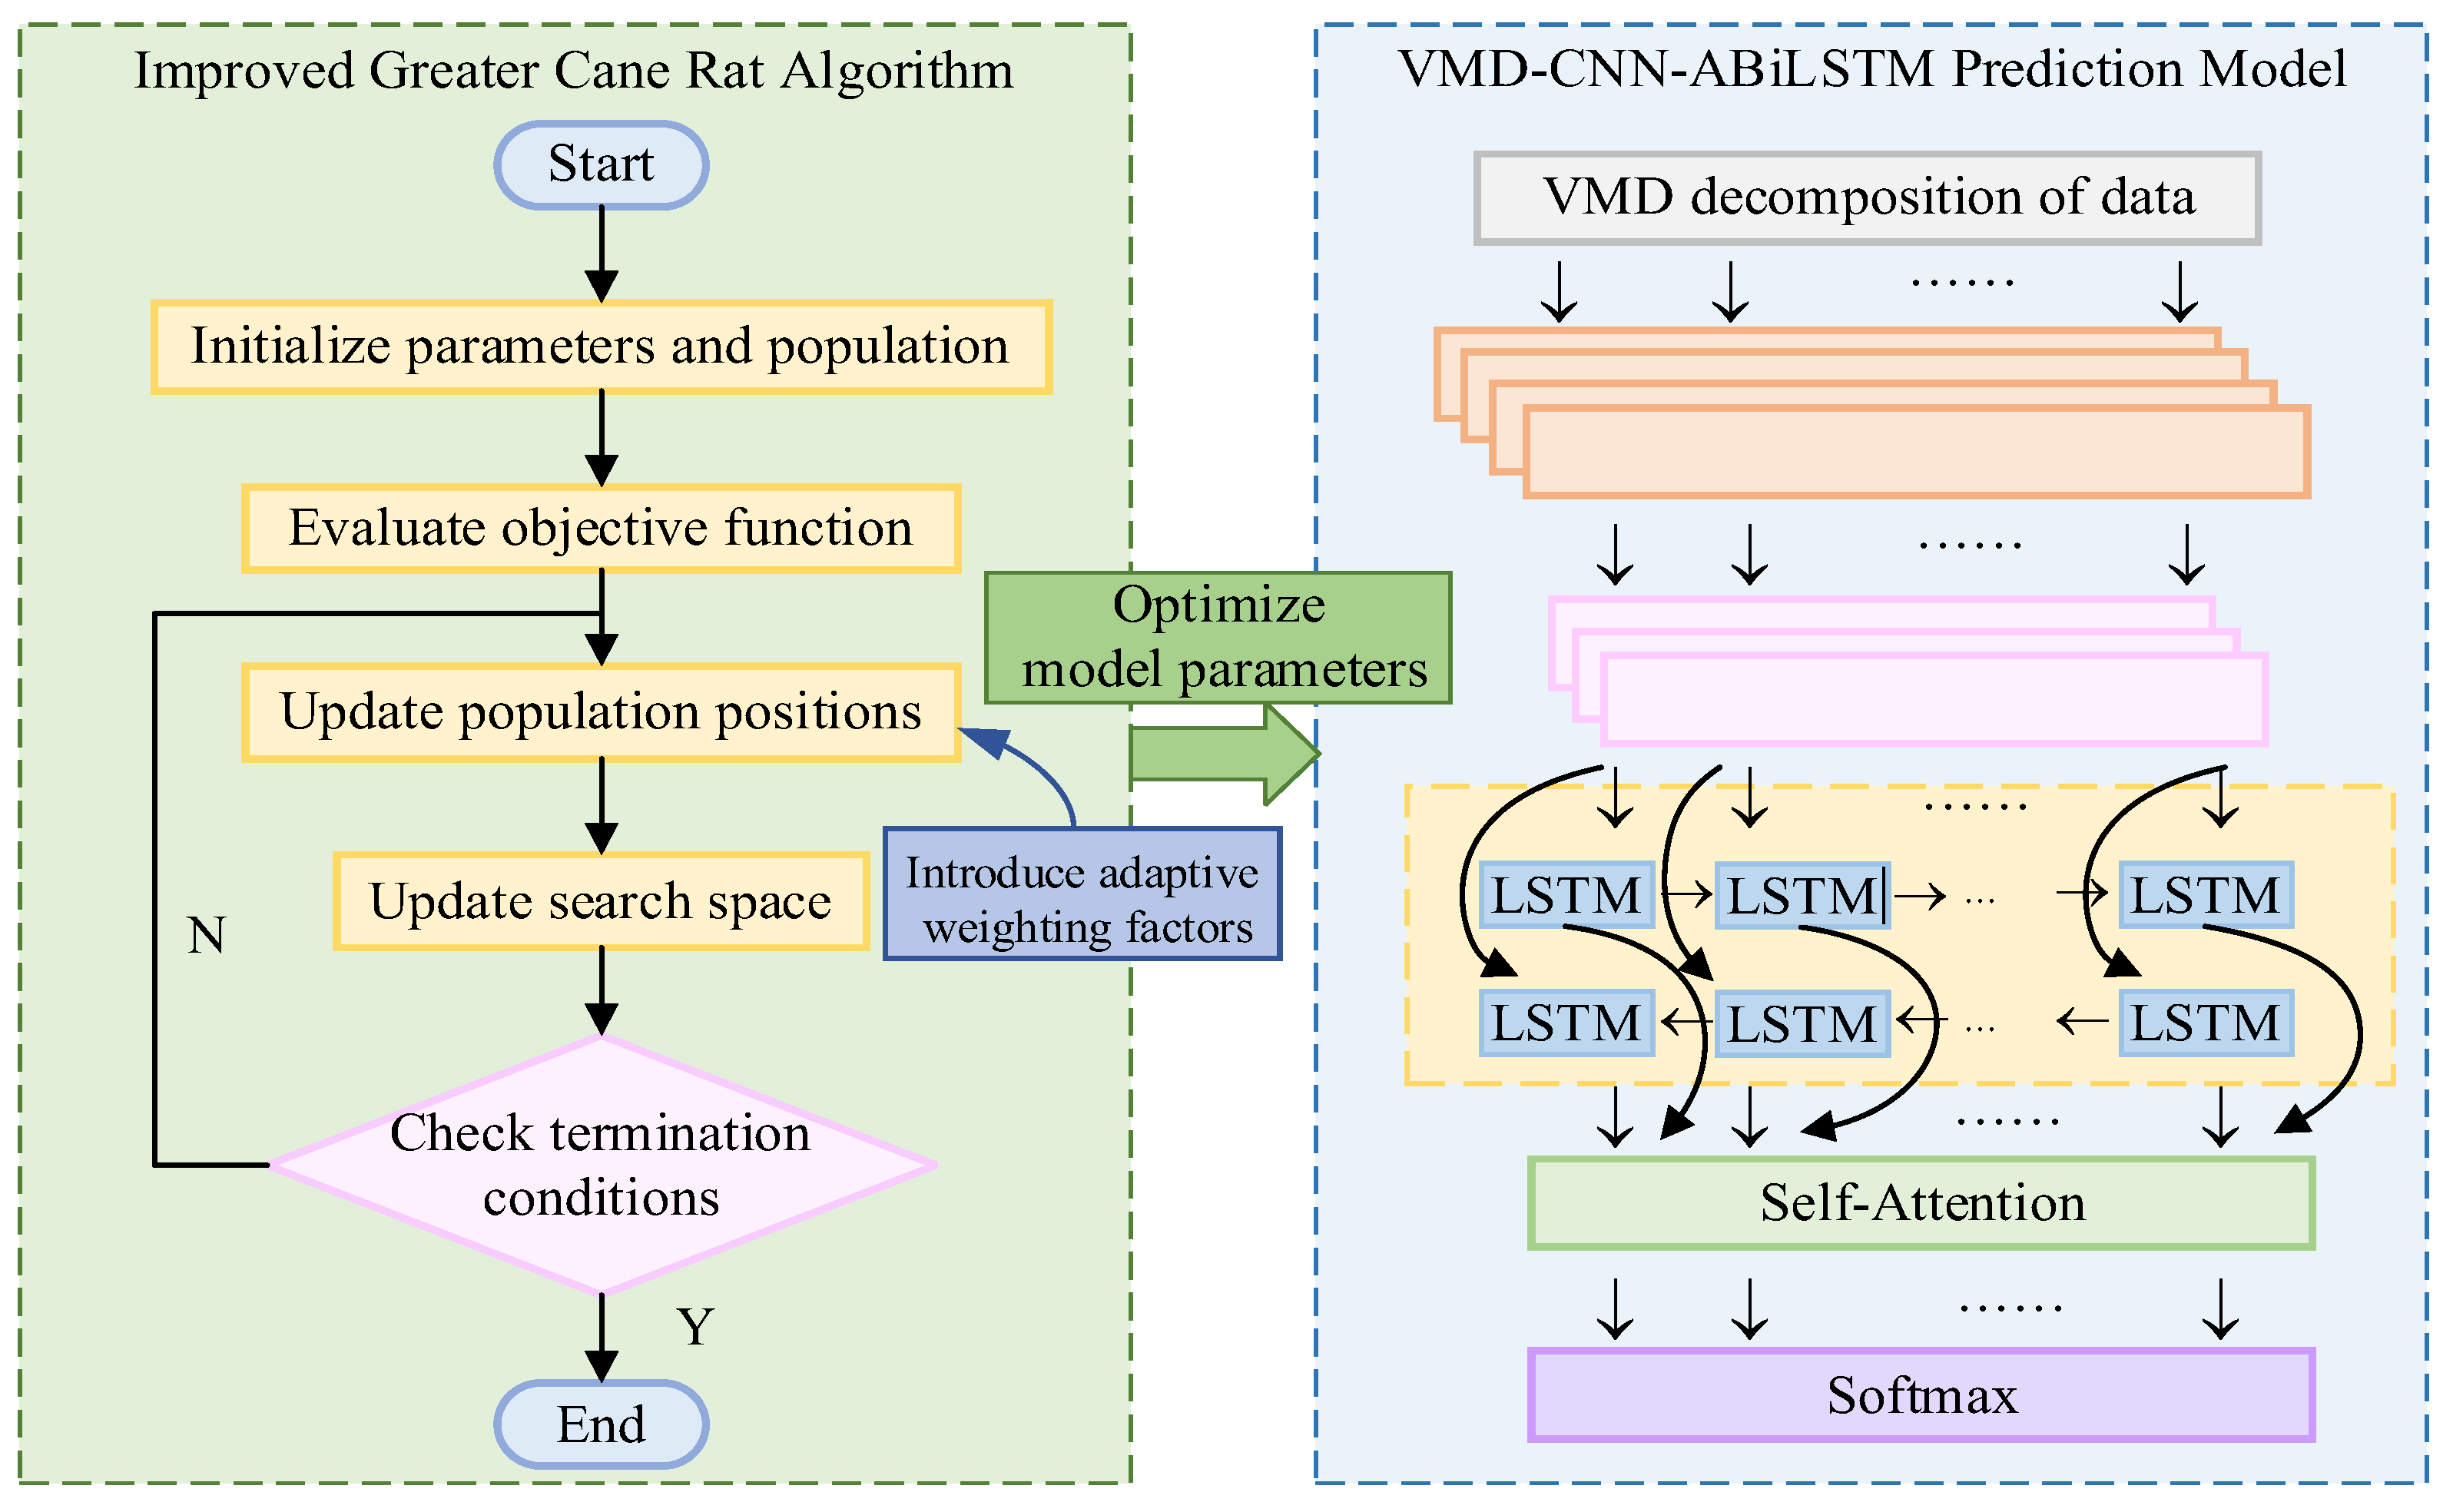
The proposed VMD-CNN-ABiLSTM-IGCRA framework forecasts EV charging demand through a decomposition–prediction–reconstruction process. First, VMD decomposes the original load series into multiple intrinsic mode functions (IMFs). Each IMF is then processed by the CNN-ABiLSTM module, where the CNN extracts local features, the BiLSTM captures long-term temporal dependencies, and the attention mechanism adaptively emphasizes informative patterns. The individual IMF forecasts are subsequently aggregated to reconstruct the final charging-load prediction. IGCRA is further employed to optimize the model hyperparameters, thereby improving predictive accuracy and robustness. The overall architecture is presented in Figure 6.
Figure 6.
The VMD-CNN-ABiLSTM-IGCRA prediction model architecture.
3. System Operation Model
3.1. Objective Function
This study formulates the objective as the minimization of total cost. The cost includes environmental cost and economic cost. The economic cost comprises operating cost, electricity purchase cost, and wind/solar power curtailment cost.
3.1.1. Economic Cost
(1) Operating Costs
In the formula, signifies the unit operating cost coefficient for wind-turbine power, denotes the wind power generation at time t; denotes the per-unit operating cost coefficient of PV modules, indicates the photovoltaic power generation at time t; corresponds to the operating cost coefficient of gas turbine generators, shows the gas turbine power generation at time t; signifies the operating cost coefficient of battery discharge units, represents the battery discharge power at time t; refers to the operating cost coefficient of battery charging, and signifies the battery’s charging power at time slot t.
(2) Electricity Purchasing Costs
In the formula, and denote, respectively, the marginal prices for electricity purchased from and sold to the grid; is a variable indicating whether to purchase electricity from the grid; and and denote the purchased power and sold power at time t respectively.
(3) Wind and Photovoltaic Curtailment Cost
In the formula, represents the wind curtailment coefficient and denotes the photovoltaic curtailment coefficient.
3.1.2. Environmental Cost
In the formula, denote the specific carbon-emission factors tied to grid imports, gas-turbine output, battery discharging, and battery charging, respectively.
3.2. Constraints
(1) Constraints of Wind Power Generation:
In the formula, represents the minimum power output of wind generation and denotes the maximum power output of wind generation.
(2) Constraints of Photovoltaic Power Generation:
In the formula, signifies the lower operating limit of PV power production and designates the upper production bound of photovoltaic generation.
(3) Constraints for Gas Turbine Power Generation:
In the formula, represents the minimum power output of gas turbine generation and denotes the maximum power output of gas turbine generation.
(4) Constraints for Battery Storage Systems:
In the formula, represents the battery depth of discharge at time t; represents the minimum battery depth of discharge; and represents the maximum battery depth of discharge.
(5) Constraints for Grid:
In the formula, signifies the upper bound on bidirectional power interchange with the main grid.
(6) Constraints for Power Balance:
To summarize, the constraints are as follows:
3.3. State-Triggered Adaptive Decision and Scheduling Mechanism
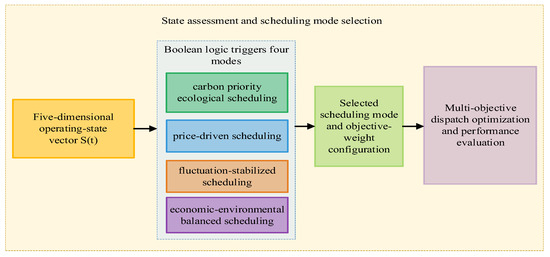
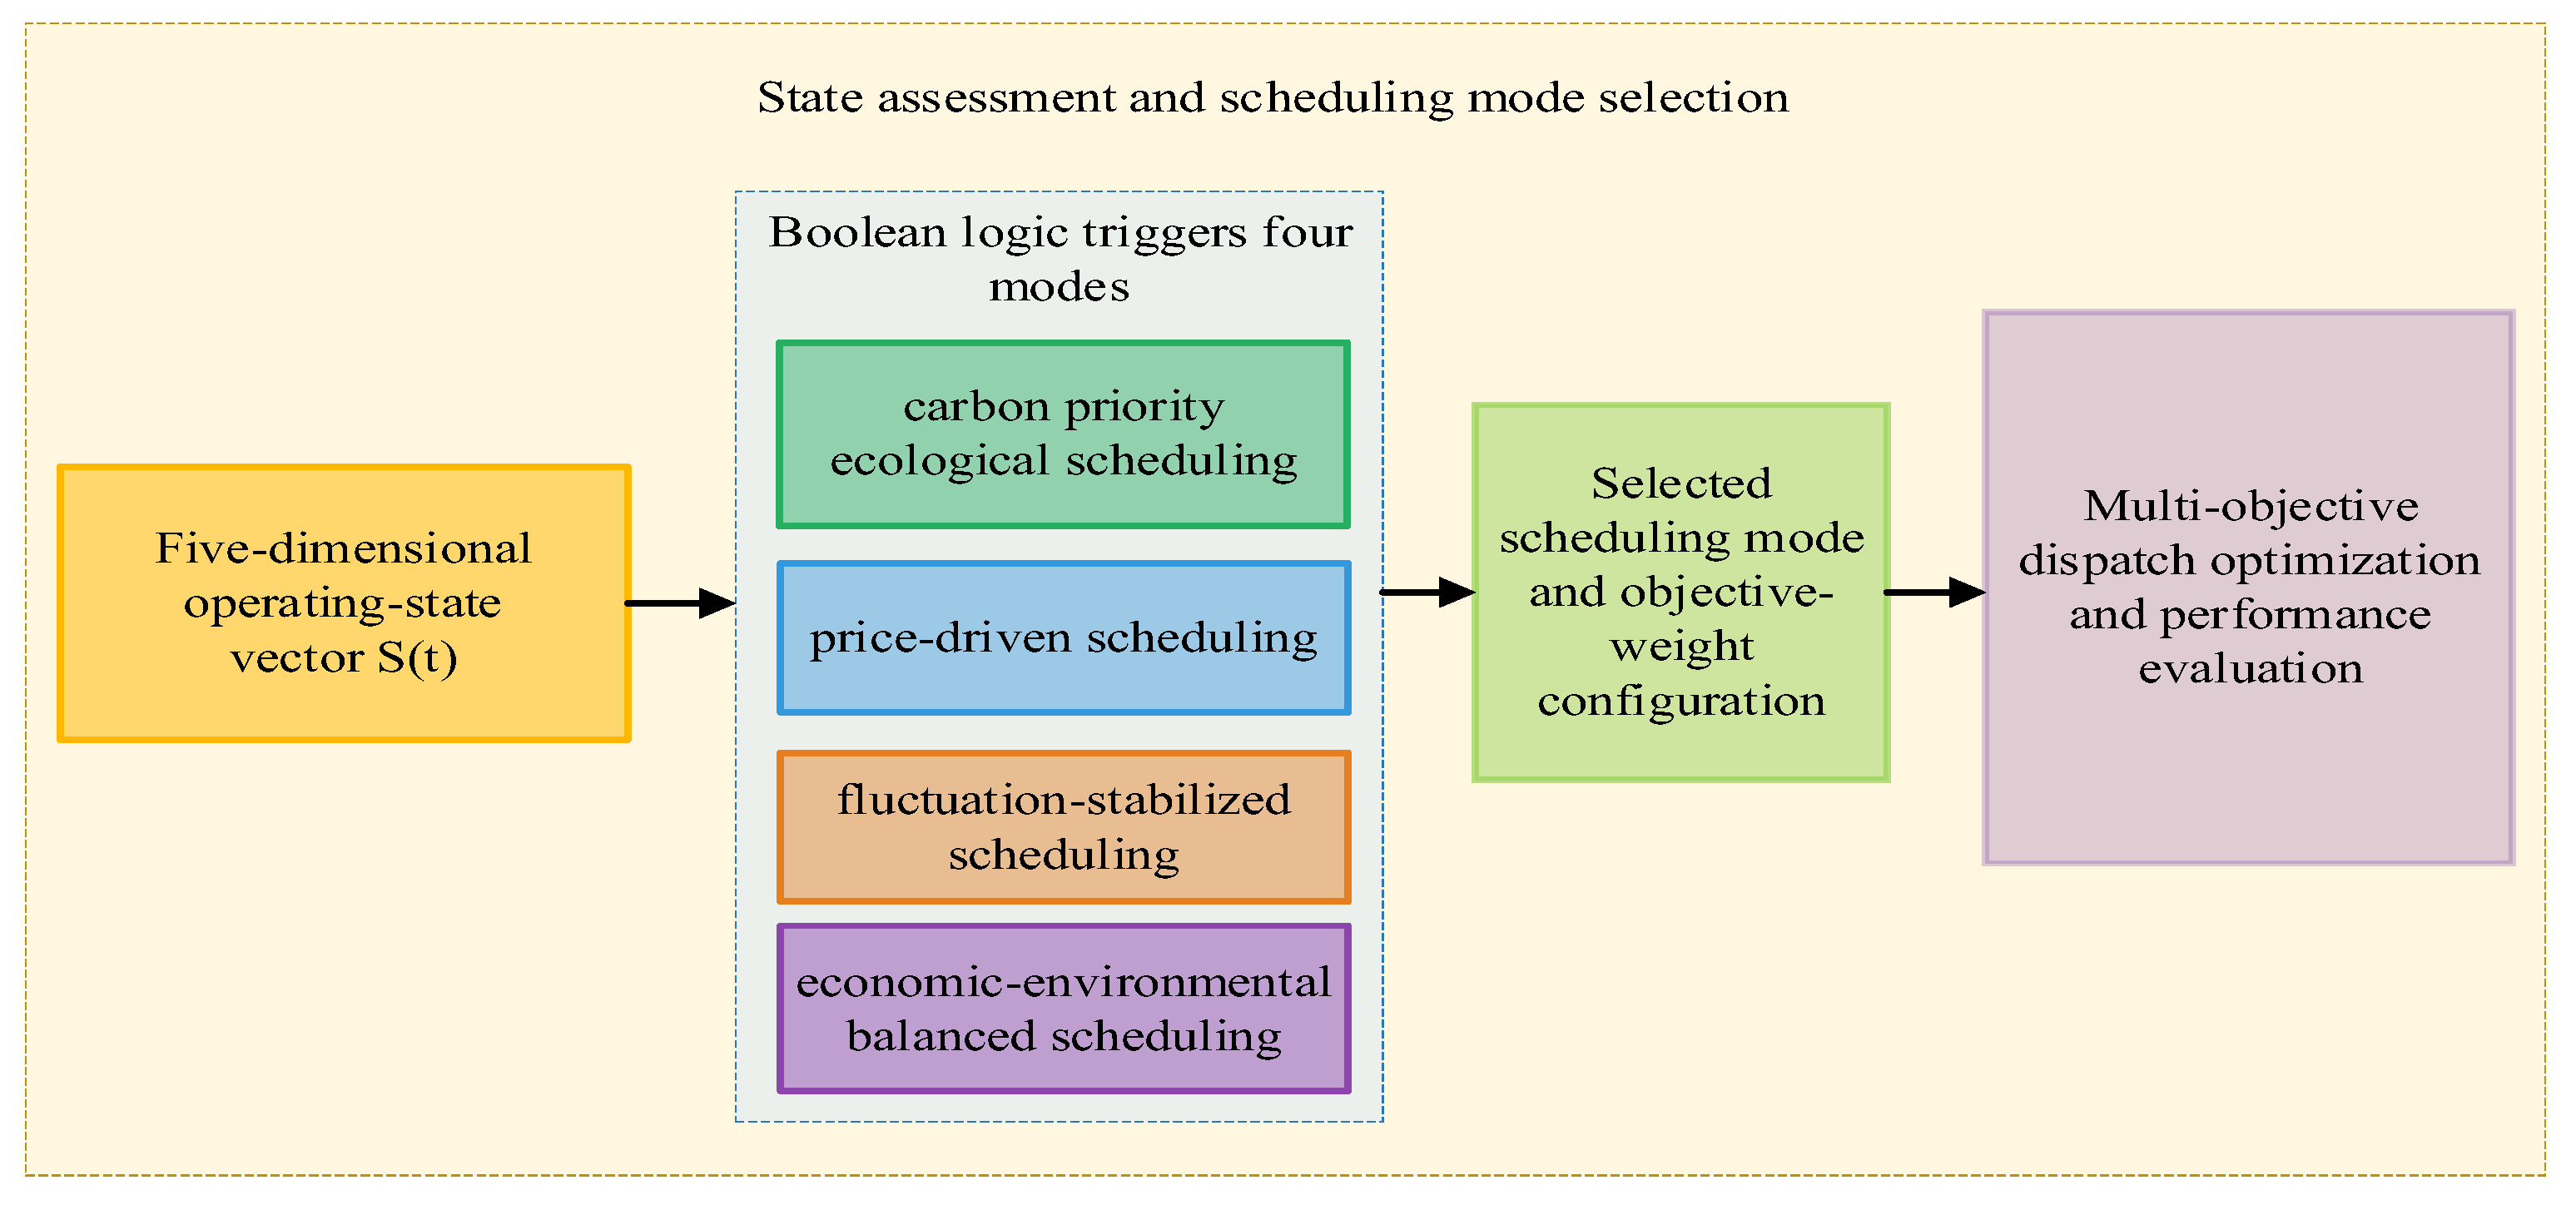
To overcome the static nature of a conventional forecast-then-optimize pipeline, this section establishes a state-triggered adaptive scheduling mechanism, as illustrated in Figure 7. The method is not a formal structural causal model in the Pearlian sense: it does not estimate a causal graph, identify structural equations from data, or perform do-operator-based counterfactual inference. Instead, the forecasting output is combined with observable price, renewable-energy, carbon, load, and battery information to form a transparent state vector. Threshold rules activate one or more candidate objective configurations, and the activated candidates are solved under the same physical constraints before the best feasible scalarized result is selected.
Figure 7.
State-triggered adaptive scheduling mechanism.
3.3.1. State-Monitoring Architecture and Scheduling Interface
The scheduling interface uses observable and predicted operating quantities. Its inputs comprise the EV charging load forecast, time-of-use electricity price, wind and photovoltaic output characteristics, grid carbon information, and battery state of charge. These quantities are organized as a state vector and are used to identify the scheduling conditions relevant to the current dispatch interval.
The forecast load defines the demand to be balanced, while the remaining state indicators describe economic, environmental, variability, and storage conditions. The selected scheduling case modifies the corresponding objective weights or penalty terms, after which the equipment set-points are obtained subject to the constraints in Section 3.2.
3.3.2. State Variables and Quantification of Decision Thresholds
A five-dimensional state-monitoring vector is constructed. Each component is evaluated against a threshold derived from the corresponding historical data, as defined below.
The thresholds are empirical operating references derived from the historical data used in the case study. They should therefore be interpreted as station- and period-dependent calibration values rather than universal constants. Applying the framework to another station, tariff regime, carbon-intensity profile, renewable mix, or battery configuration would require recalibration of the corresponding historical reference distributions and thresholds.
(1) Electricity price sensitivity index
where is the current electricity purchase price at time t; and are the average and standard deviation of electricity purchase price in the dispatching period, respectively; and is the threshold of electricity price, taking the 75% quantile of historical data of electricity price.
(2) Renewable-energy volatility index
where and are the approximate entropies of wind power and photovoltaic based on rolling window, respectively; and are the rated installed capacity of wind turbines and photovoltaic units respectively; is the trigger threshold of high fluctuation mode; and and represent the moving averages of historical wind power and photovoltaic power entropy values, respectively.
(3) Predicted charging-load level index
where the numerator represents the predicted EV charging load and the denominator is the historical reference load level; the associated threshold identifies a high-load operating condition.
(4) Grid Carbon-Pressure Index
where stands for environmental cost benchmark weight; stands for carbon intensity correction coefficient of power grid; stands for grid interactive power; stands for total power consumption of the system; stands for the trigger threshold of carbon-priority ecological model; stands for marginal environmental cost; and stands for economic marginal cost.
(5) Available battery-capacity ratio
where represents the state of charge of the battery at time T; and represent the maximum and minimum battery capacity; and stands for low-capacity warning threshold.
3.3.3. Four-Mode State-Triggered Dispatch Logic
Boolean threshold rules activate one or more candidate operating modes. The retained case numbering used throughout the case study is Case 1 carbon-priority scheduling, Case 2 price-driven scheduling, Case 3 fluctuation-stabilized scheduling, and Case 4 economic–environmental balanced scheduling.
Mode F1 represents a price-driven scalarization. When the electricity-price condition is activated, the coefficient assigned to is increased, while the relative contribution of is attenuated.
where stands for hyperbolic tangent saturation function; stands for linear rectification limiting function; stands for electricity price sensitive gain coefficient; and stands for environmental weight attenuation coefficient.
Mode F2 retains the economic and environmental cost terms and introduces an additional monetary-equivalent penalty for source–load power deviation when renewable-energy volatility exceeds the specified threshold.
where represents the benchmark coefficient of fluctuation punishment.
Mode F3 represents a carbon-priority scalarization. When the carbon-pressure condition is activated, the relative contribution of is increased and an additional penalty is imposed on the gas-turbine output.
where stands for gas suppression gain coefficient; stands for Heaviside step function; and stands for environmental enhancement gain factor.
Mode F4 represents the economic–environmental balanced scalarization. When no single priority condition dominates, non-negative coefficients and , satisfying , are used to coordinate and .
where and stand for the weight coefficients.
3.3.4. Mode Selection and Dispatch Output
When several trigger conditions are satisfied simultaneously, the corresponding scheduling modes are treated as candidate configurations. Each candidate is solved under the same equipment constraints, power-balance constraint, forecast input, and dispatch horizon. The economic, environmental, and penalty components are expressed in monetary or monetary-equivalent units according to the general scalar formulation in Section 3.1. This provides a consistent basis for comparing the feasible candidate solutions. The candidate with the minimum state-dependent comprehensive objective is selected for implementation. If no special priority condition is activated, Case 4 is adopted as the default coordinated mode. The selected mode determines the objective coefficients and penalty parameters used to calculate the WT, PV, GT, battery, and grid set-points. The selected solution should be interpreted as a state-dependent operational compromise rather than as the complete Pareto-optimal set of the original multi-criteria problem.
The dispatch decision variables are the controllable power set-points of the wind, photovoltaic, gas-turbine, battery charge/discharge, and grid purchase/sale channels over the dispatch horizon. Each candidate mode changes the scalar objective coefficients and/or penalty terms, while feasibility is enforced through the equipment limits and power-balance constraints in Section 3.2. The selected result is therefore a feasible state-dependent scalarized dispatch solution, not the complete Pareto-optimal front of the underlying multi-criteria problem.
4. Case Study
4.1. Data Source
This study uses one month of hourly charging load data collected from public EV charging piles in Shenzhen. The dataset covers 31 consecutive days, from 19 June to 18 July 2022, and contains 24 observations per day. These data are used to train and evaluate the forecasting model and to support the subsequent microgrid scheduling and energy-allocation analysis.
Dataset 1: The charging load data of Public Charging Pile 1 in Shenzhen, comprising a total of 744 sampling points;
Dataset 2: The charging load data of Public Charging Pile 2 in Shenzhen, comprising a total of 744 sampling points;
Dataset 3: The charging load data of Public Charging Pile 3 in Shenzhen, comprising a total of 744 sampling points.
4.2. Data Preprocessing, Chronological Partition, and Evaluation Scope
Each dataset was divided chronologically, with the first 70% of observations used for model development and the final 30% used for out-of-sample testing. Normalization parameters and decomposition settings were determined from the training portion and then applied to the test portion to reduce look-ahead leakage. Dataset 1 was additionally used to compare VMD, EMD, and CEEMDAN under a common CNN-ABiLSTM architecture. Performance was assessed using RMSE, MAE, SMAPE, and R2. For VMD, the penalty-factor search range was [500, 1000] and the number of decomposition modes was fixed at K = 5. K was treated as a common preprocessing configuration rather than an optimized variable; therefore, the current results do not establish K = 5 as a globally optimal choice.
Because each station contains only 744 hourly observations (31 days), the forecasting results require cautious interpretation. The chronological split is more appropriate than a random split for preserving temporal order, and L2 regularization is used during network training; the results should be interpreted as numerical performance on the reported case-study period.
Table 1 compares the predictive performance of VMD-CNN-ABiLSTM, EMD-CNN-ABiLSTM, and CEEMDAN-CNN-ABiLSTM using RMSE, MAE, SMAPE, and R2. Among the three models, VMD-CNN-ABiLSTM achieves the best overall results, with an RMSE of 5.8534, an MAE of 4.5181, an SMAPE of 7.7263%, and an R2 of 93.5394%. CEEMDAN-CNN-ABiLSTM ranks second, whereas EMD-CNN-ABiLSTM yields the highest errors and the lowest R2. These results indicate that VMD provides more effective signal decomposition for this dataset, leading to lower prediction errors and a better fit to the observed charging-load series.
Table 1.
Comparison results of three decomposition algorithms for Dataset 1.
4.3. Model Parameters
The proposed VMD-CNN-ABiLSTM-IGCRA model is configured using the hyperparameters listed in Table 2. The convolutional layer contains 64 filters to balance local feature extraction with computational cost, while max pooling with a window size of 2 reduces redundant information and preserves dominant patterns. The fully connected layer includes 25 neurons to support nonlinear representation learning. Model training is performed with the Adam optimizer for up to 200 epochs, with the gradient norm clipped at 1 to prevent instability. The initial learning rate is set to 0.01 and reduced by a factor of 0.01 every 100 epochs. An L2 regularization coefficient of 0.001 is applied to limit overfitting and improve generalization. All experiments are conducted on a GPU to accelerate training and model evaluation.
Table 2.
Parameters of models.
4.4. Evaluation Indicators
Four complementary metrics are adopted to appraise predictive quality: Root Mean Square Error (RMSE), Mean Absolute Error (MAE), Symmetric Mean Absolute Percentage Error (SMAPE) and Coefficient of Determination (R2). Collectively they expose accuracy and fidelity from distinct angles; their analytical expressions are given below.
In the expressions, denotes the sample count; is the true value; is the predicted value; and is the mean value of the samples.
5. Experimental Results and Discussion
5.1. The Performance Evaluation for VMD-CNN-ABiLSTM-IGCRA Model
To evaluate the proposed VMD-CNN-ABiLSTM-IGCRA framework, its forecasting performance is compared with several benchmark and hybrid models across all three datasets. For clarity, the competing models are denoted as M1–M9, as listed in Table 3.
Table 3.
Code name of each model.
5.1.1. Evaluation of Model Performance for Dataset 1
Using Dataset 1, the forecasting performance of four baseline models—Random Forest (RF), Convolutional Neural Network (CNN), Long Short-Term Memory (LSTM), and Bidirectional Long Short-Term Memory (BiLSTM)—is first evaluated. Five hybrid architectures are then examined: CNN-BiLSTM, CNN-BiLSTM-Attention, VMD-CNN-ABiLSTM, VMD-CNN-ABiLSTM-GCRA, and the proposed VMD-CNN-ABiLSTM-IGCRA.
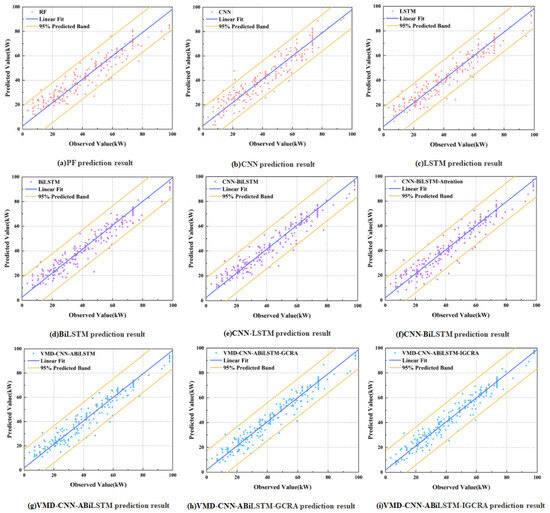
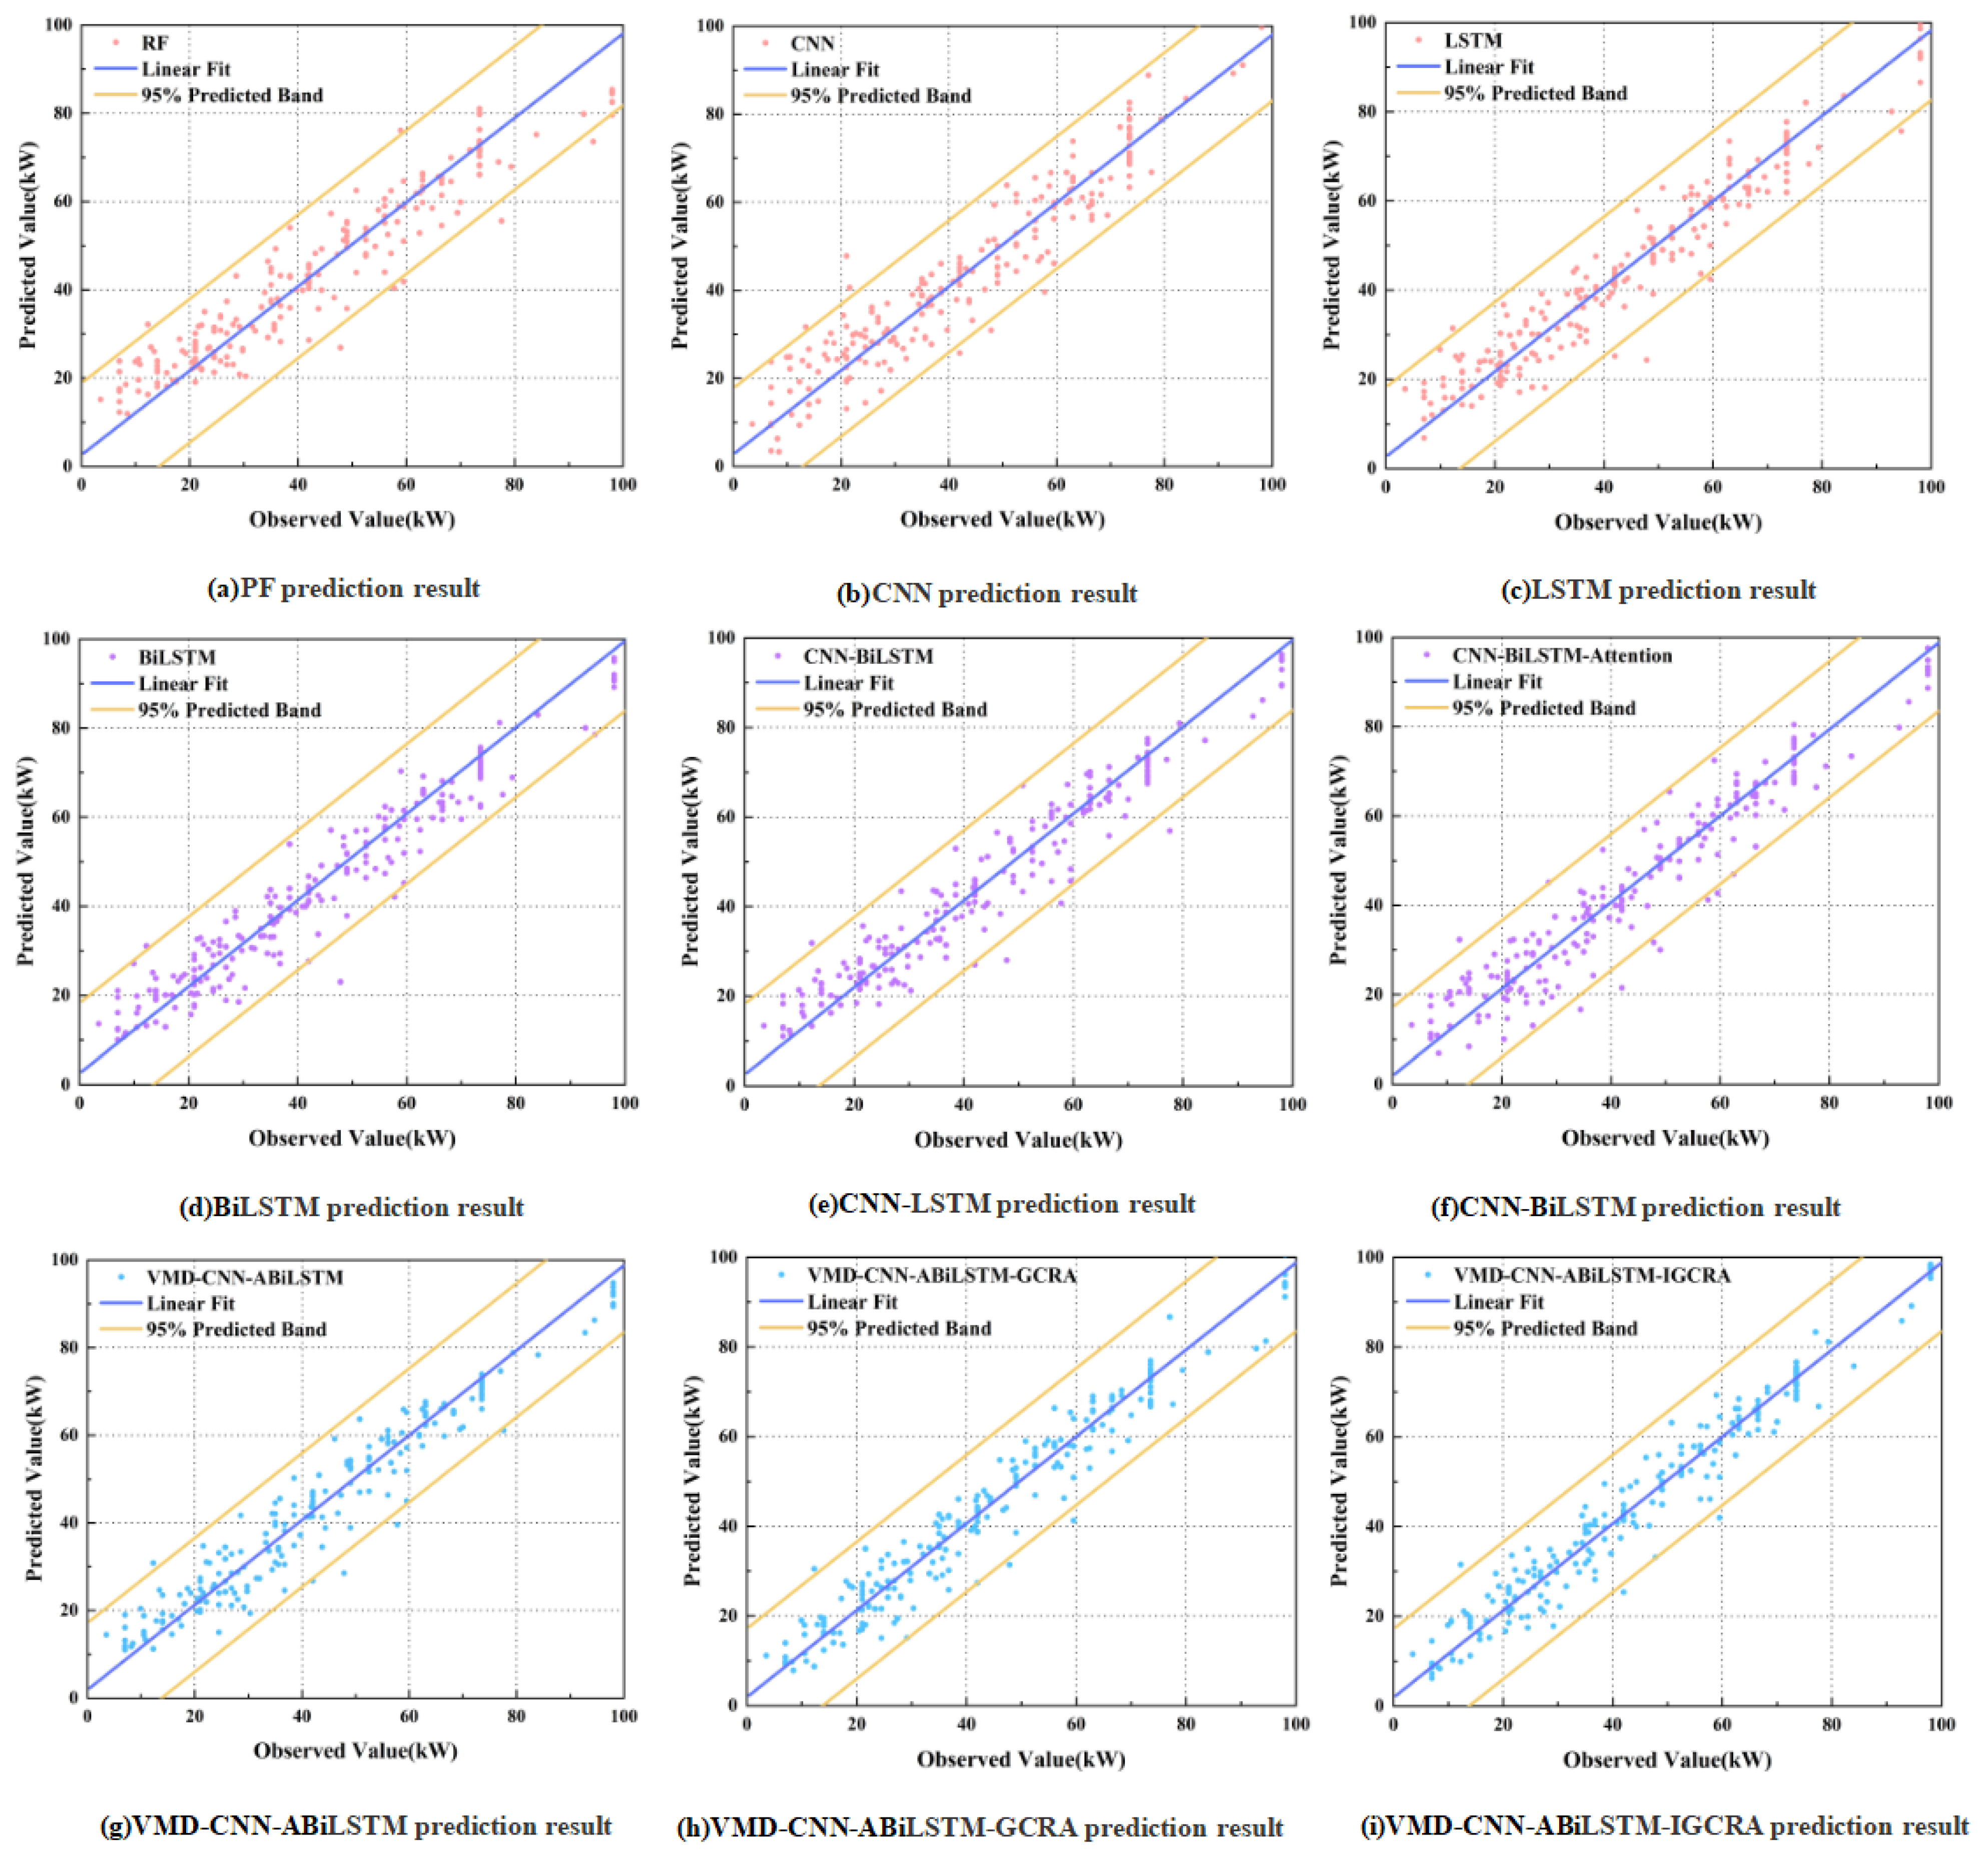
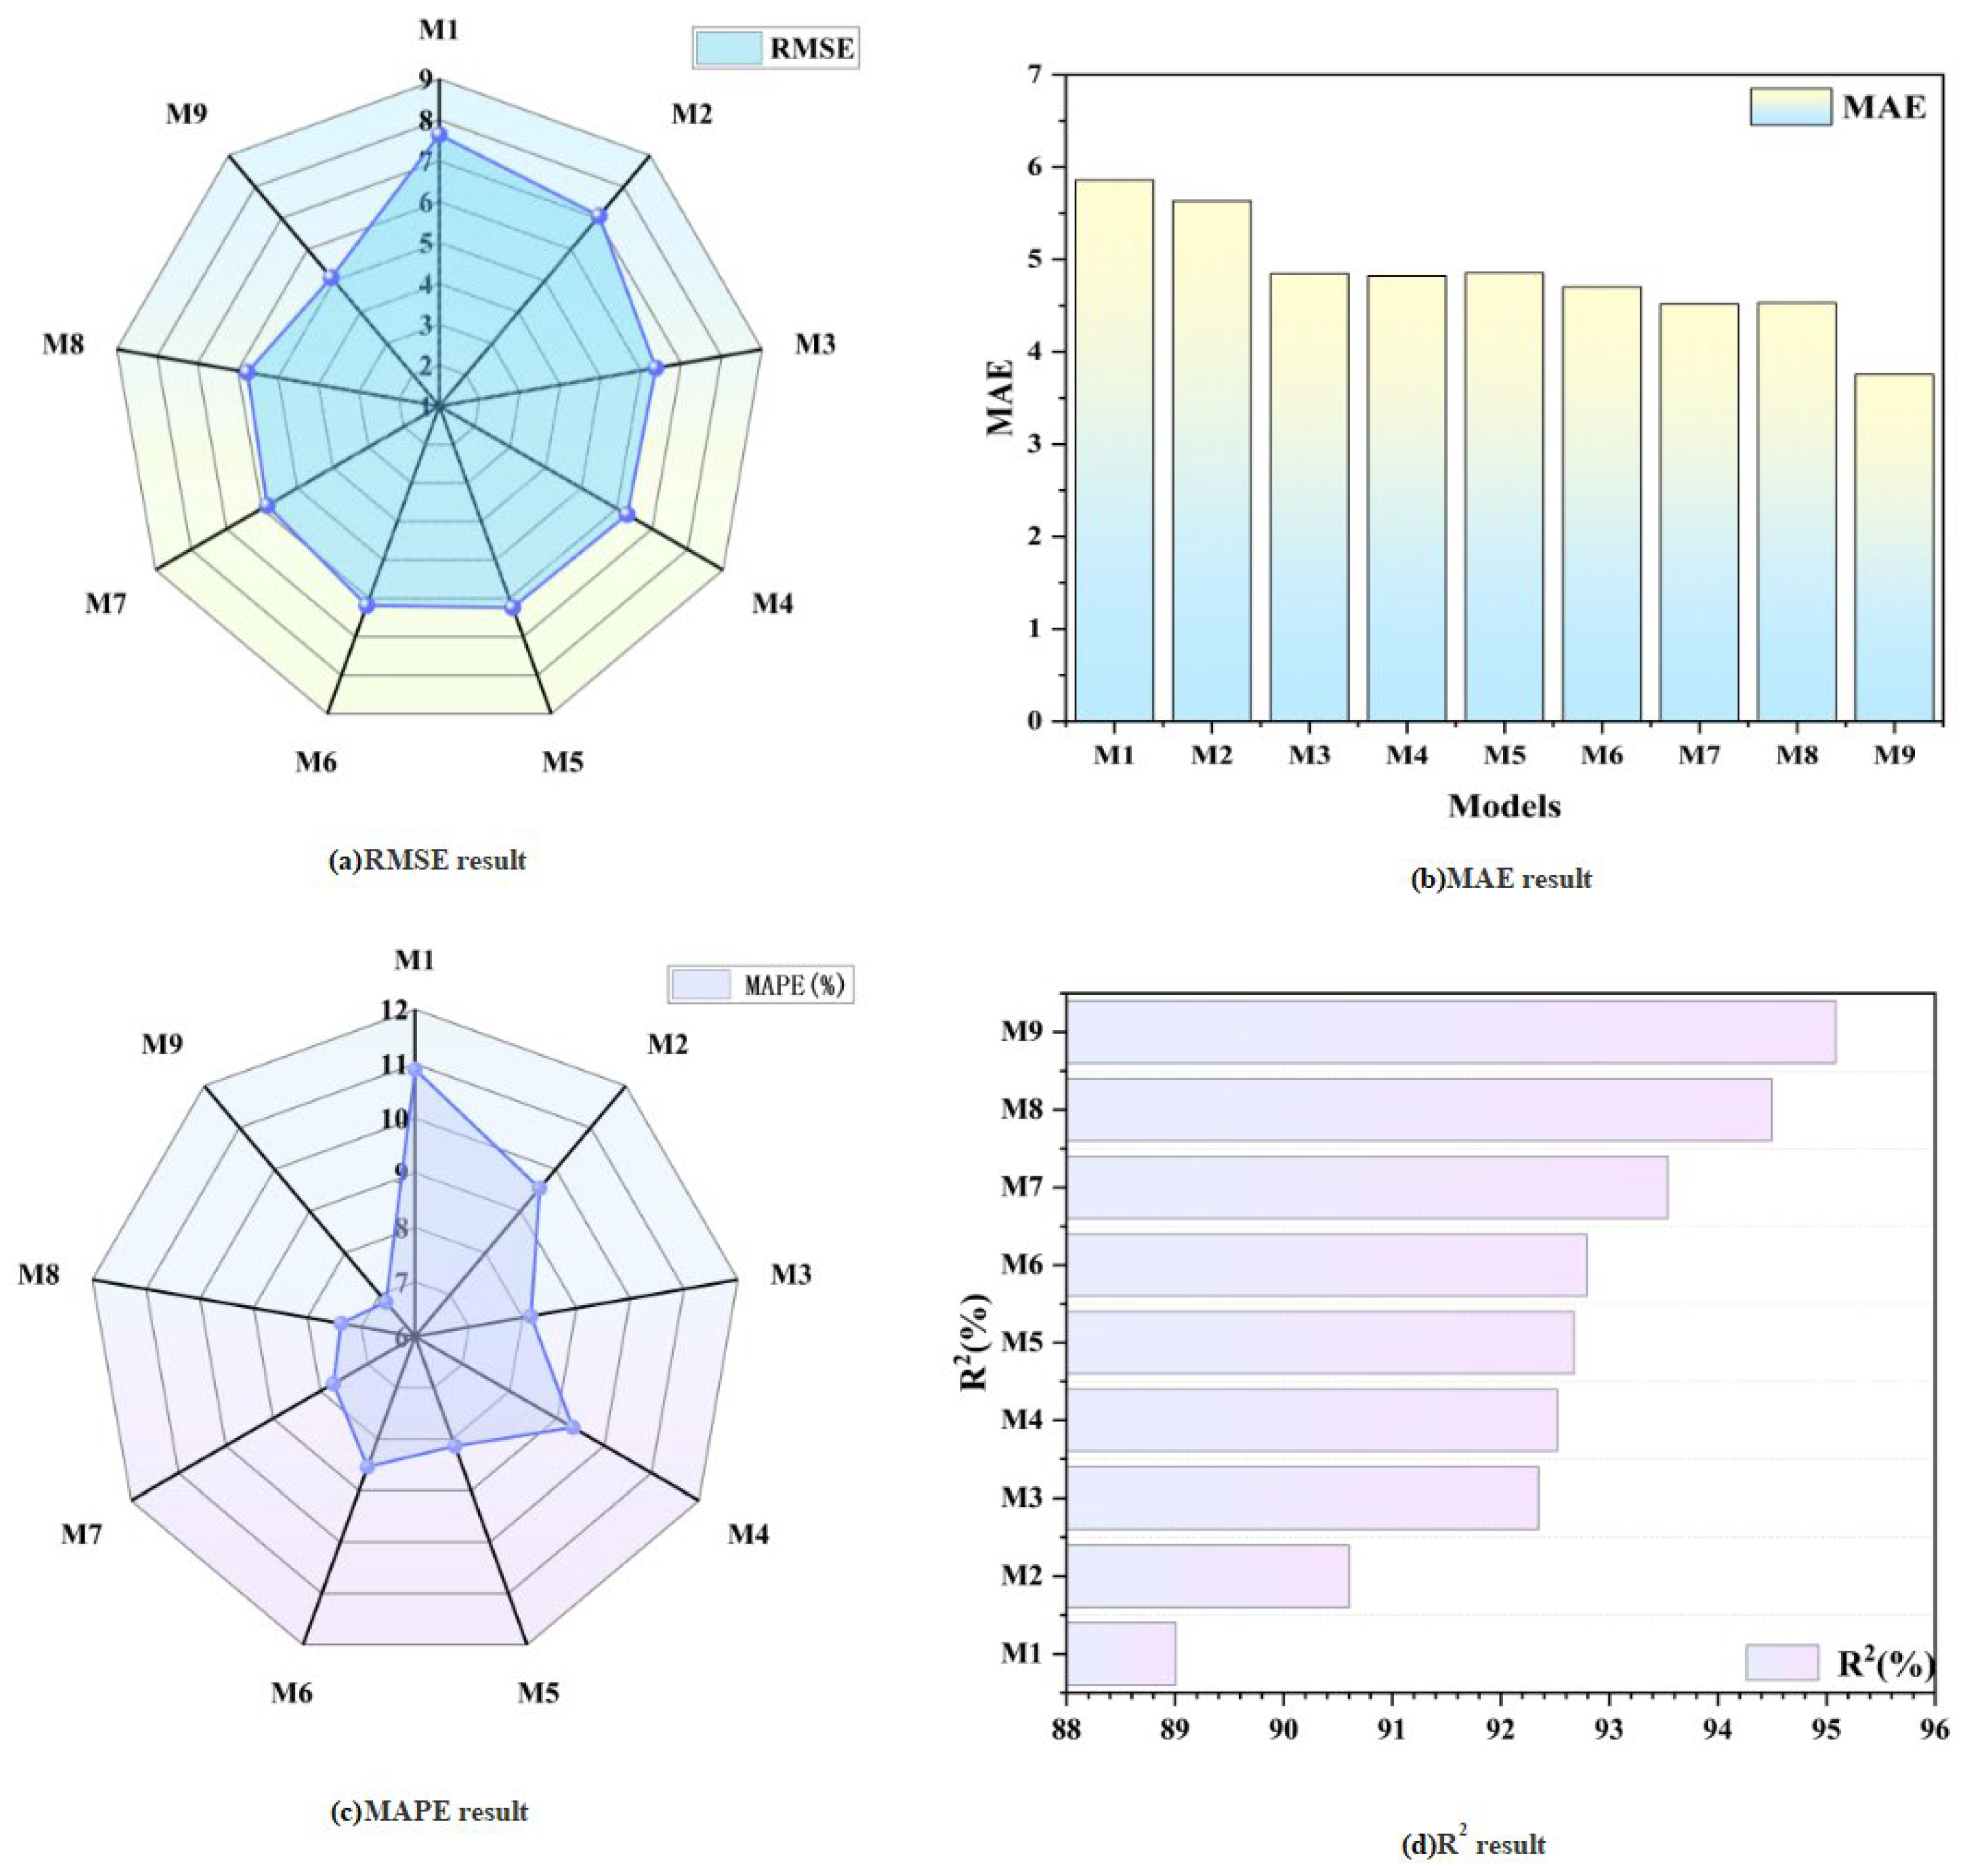
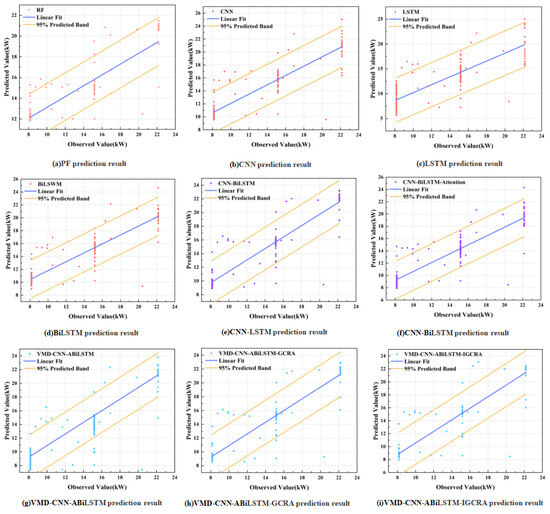
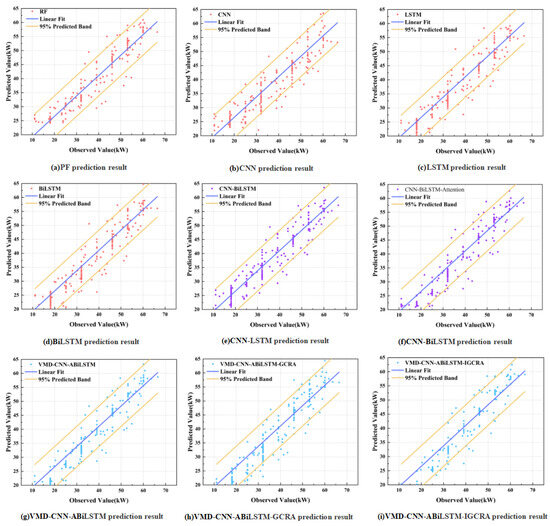
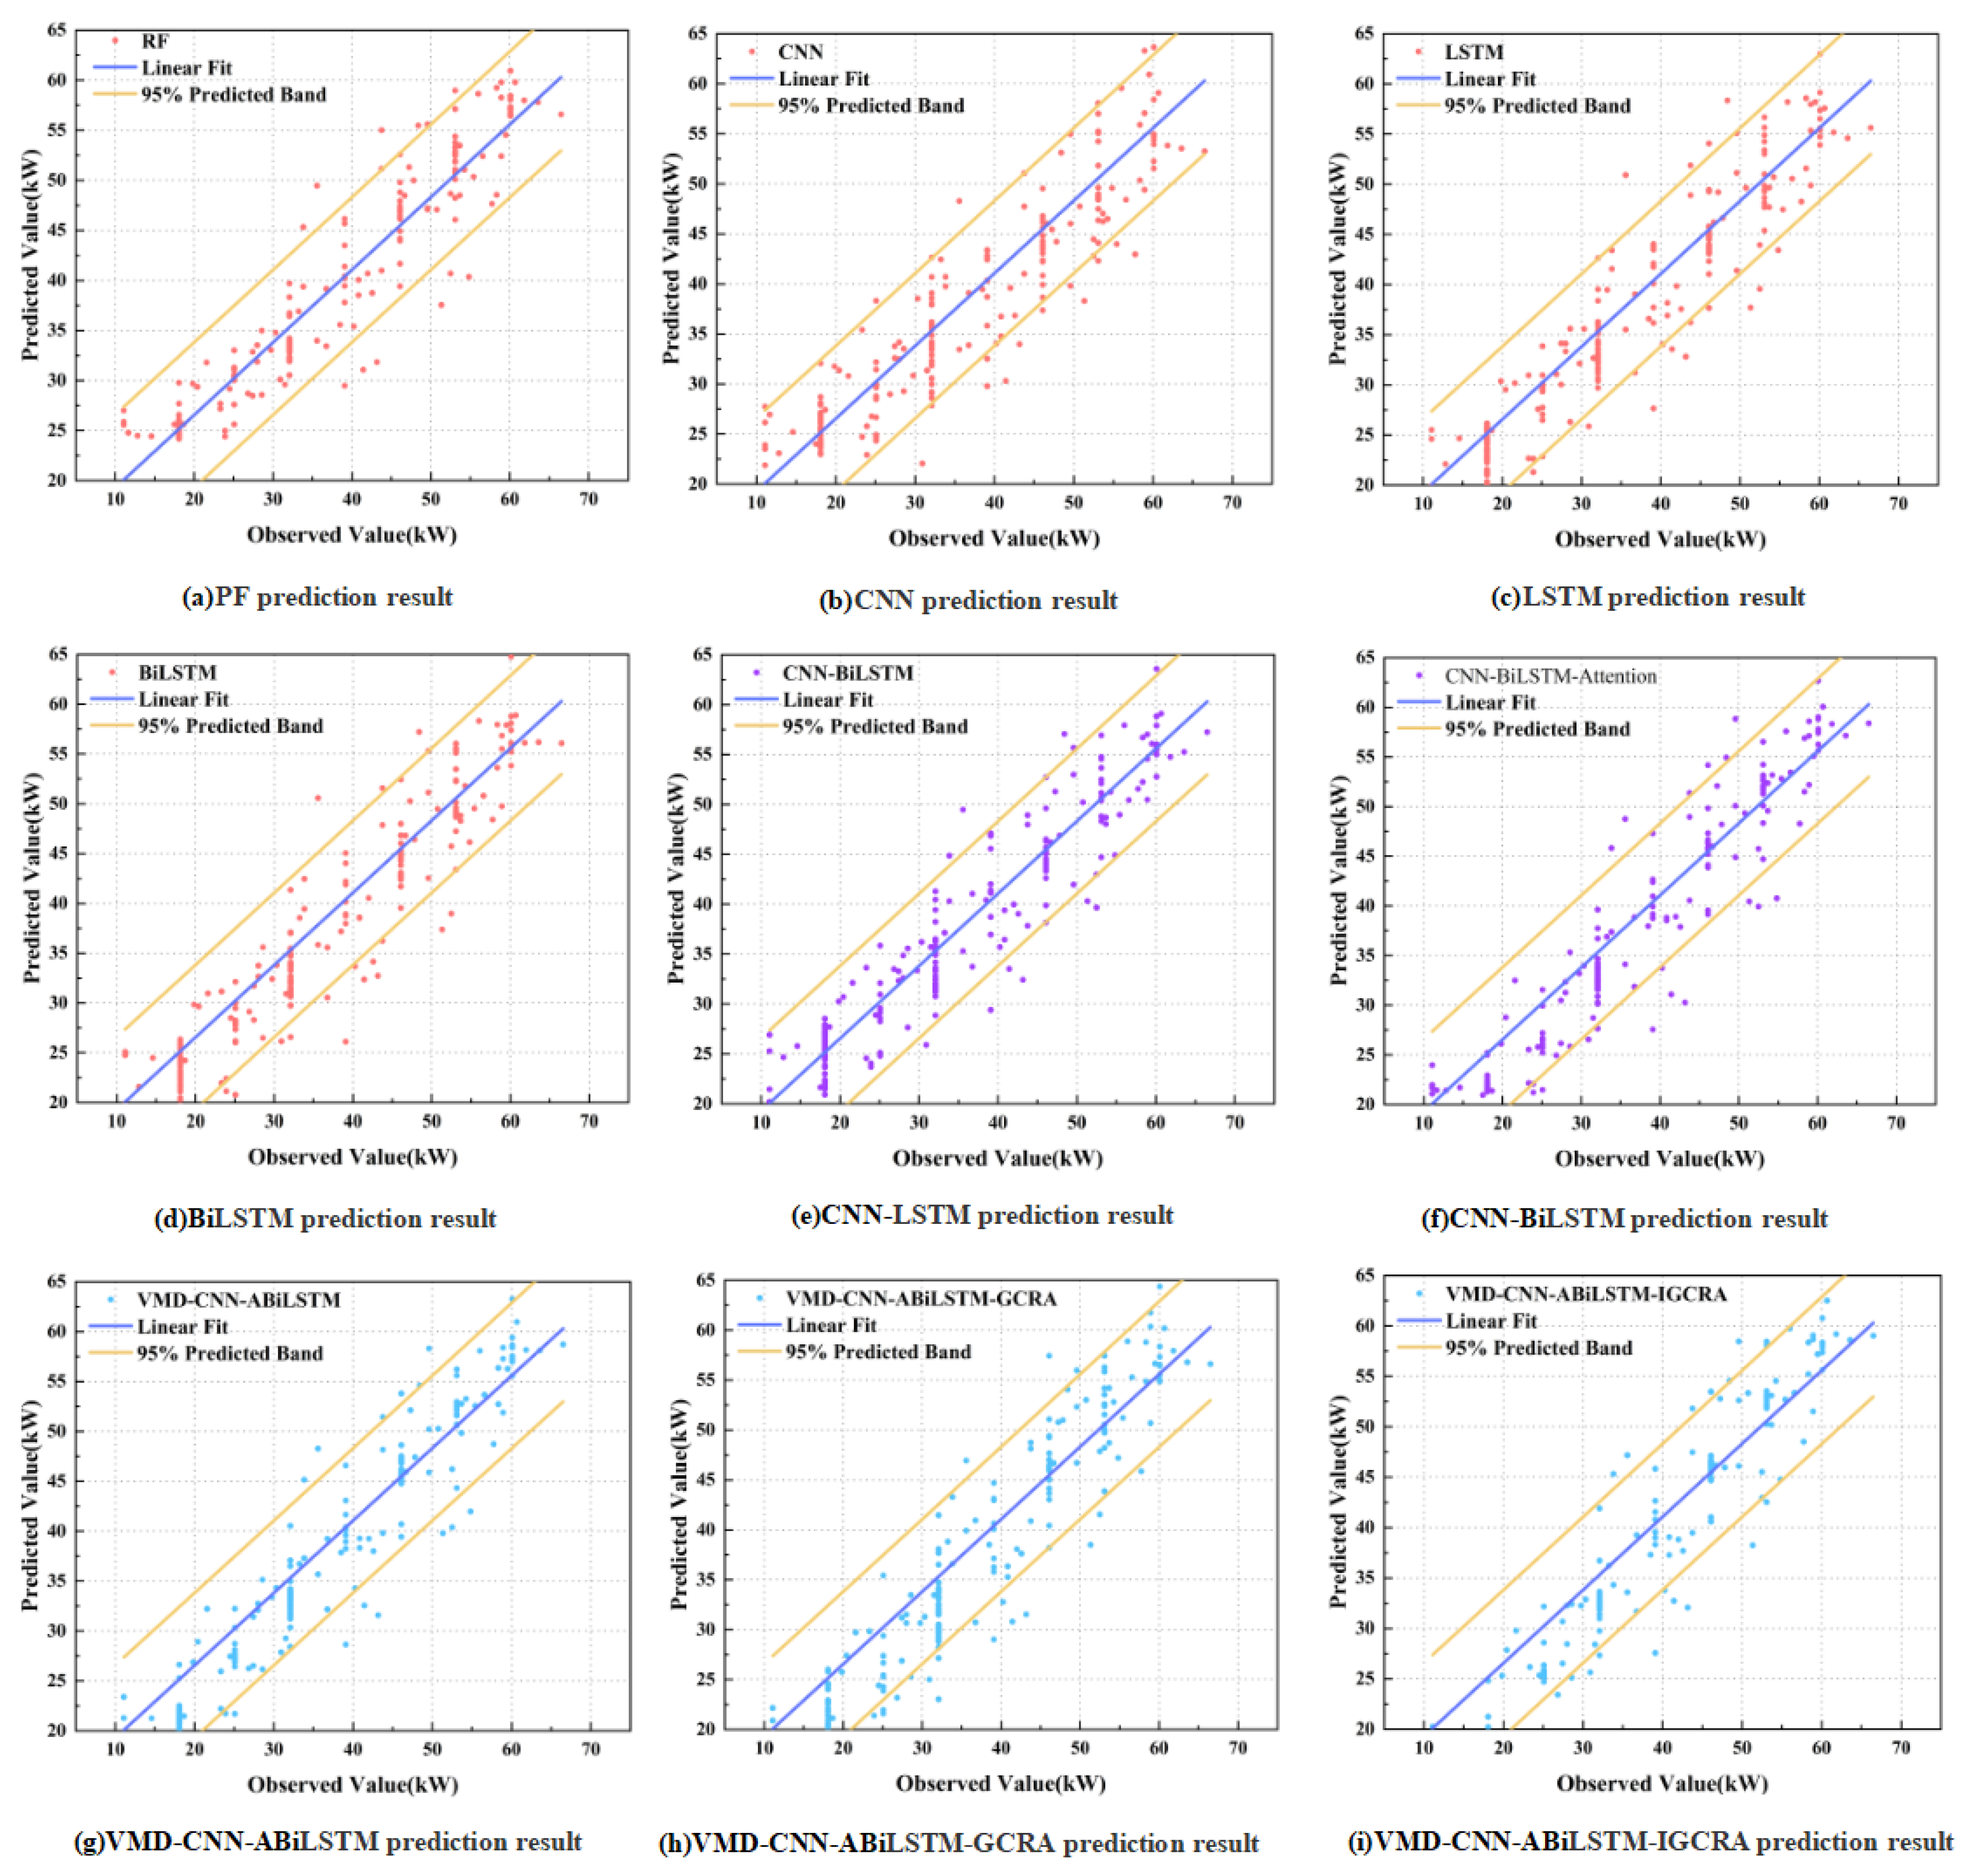
Figure 8 presents scatter plots of predicted versus observed values for Dataset 1, together with fitted regression lines and 95% prediction bands. All models show a positive association between predictions and observations, although the width of the prediction bands varies considerably. RF, CNN, and LSTM produce relatively wide bands and more dispersed points, indicating greater predictive uncertainty. By contrast, BiLSTM, CNN-BiLSTM, CNN-BiLSTM-Attention, and VMD-CNN-ABiLSTM yield tighter distributions around the fitted line, reflecting improved temporal feature representation. Further gains are observed for VMD-CNN-ABiLSTM-GCRA, owing to VMD-based signal decomposition, attention-guided feature weighting, and GCRA-based parameter optimization. The proposed VMD-CNN-ABiLSTM-IGCRA model provides the narrowest prediction bands and the closest agreement between predicted and observed values, suggesting improved stability and accuracy for highly variable EV charging load forecasting.
Figure 8.
Linear regression plots between predicted values and true values based on Dataset 1.
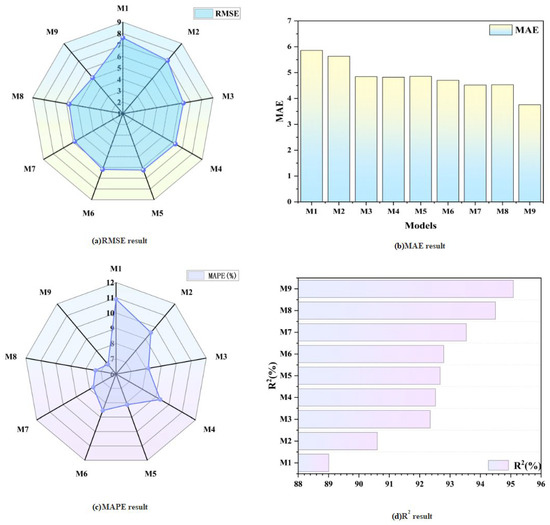
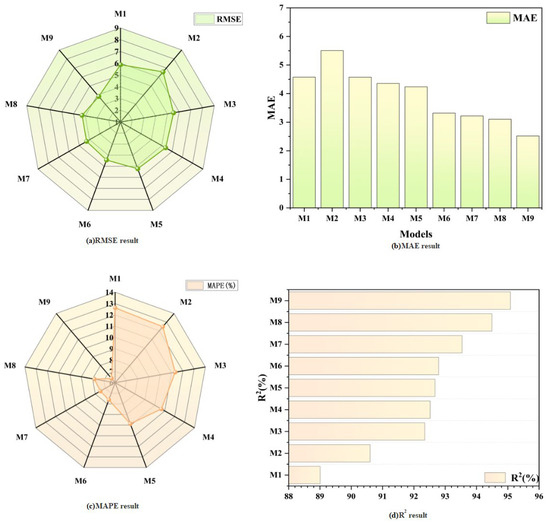
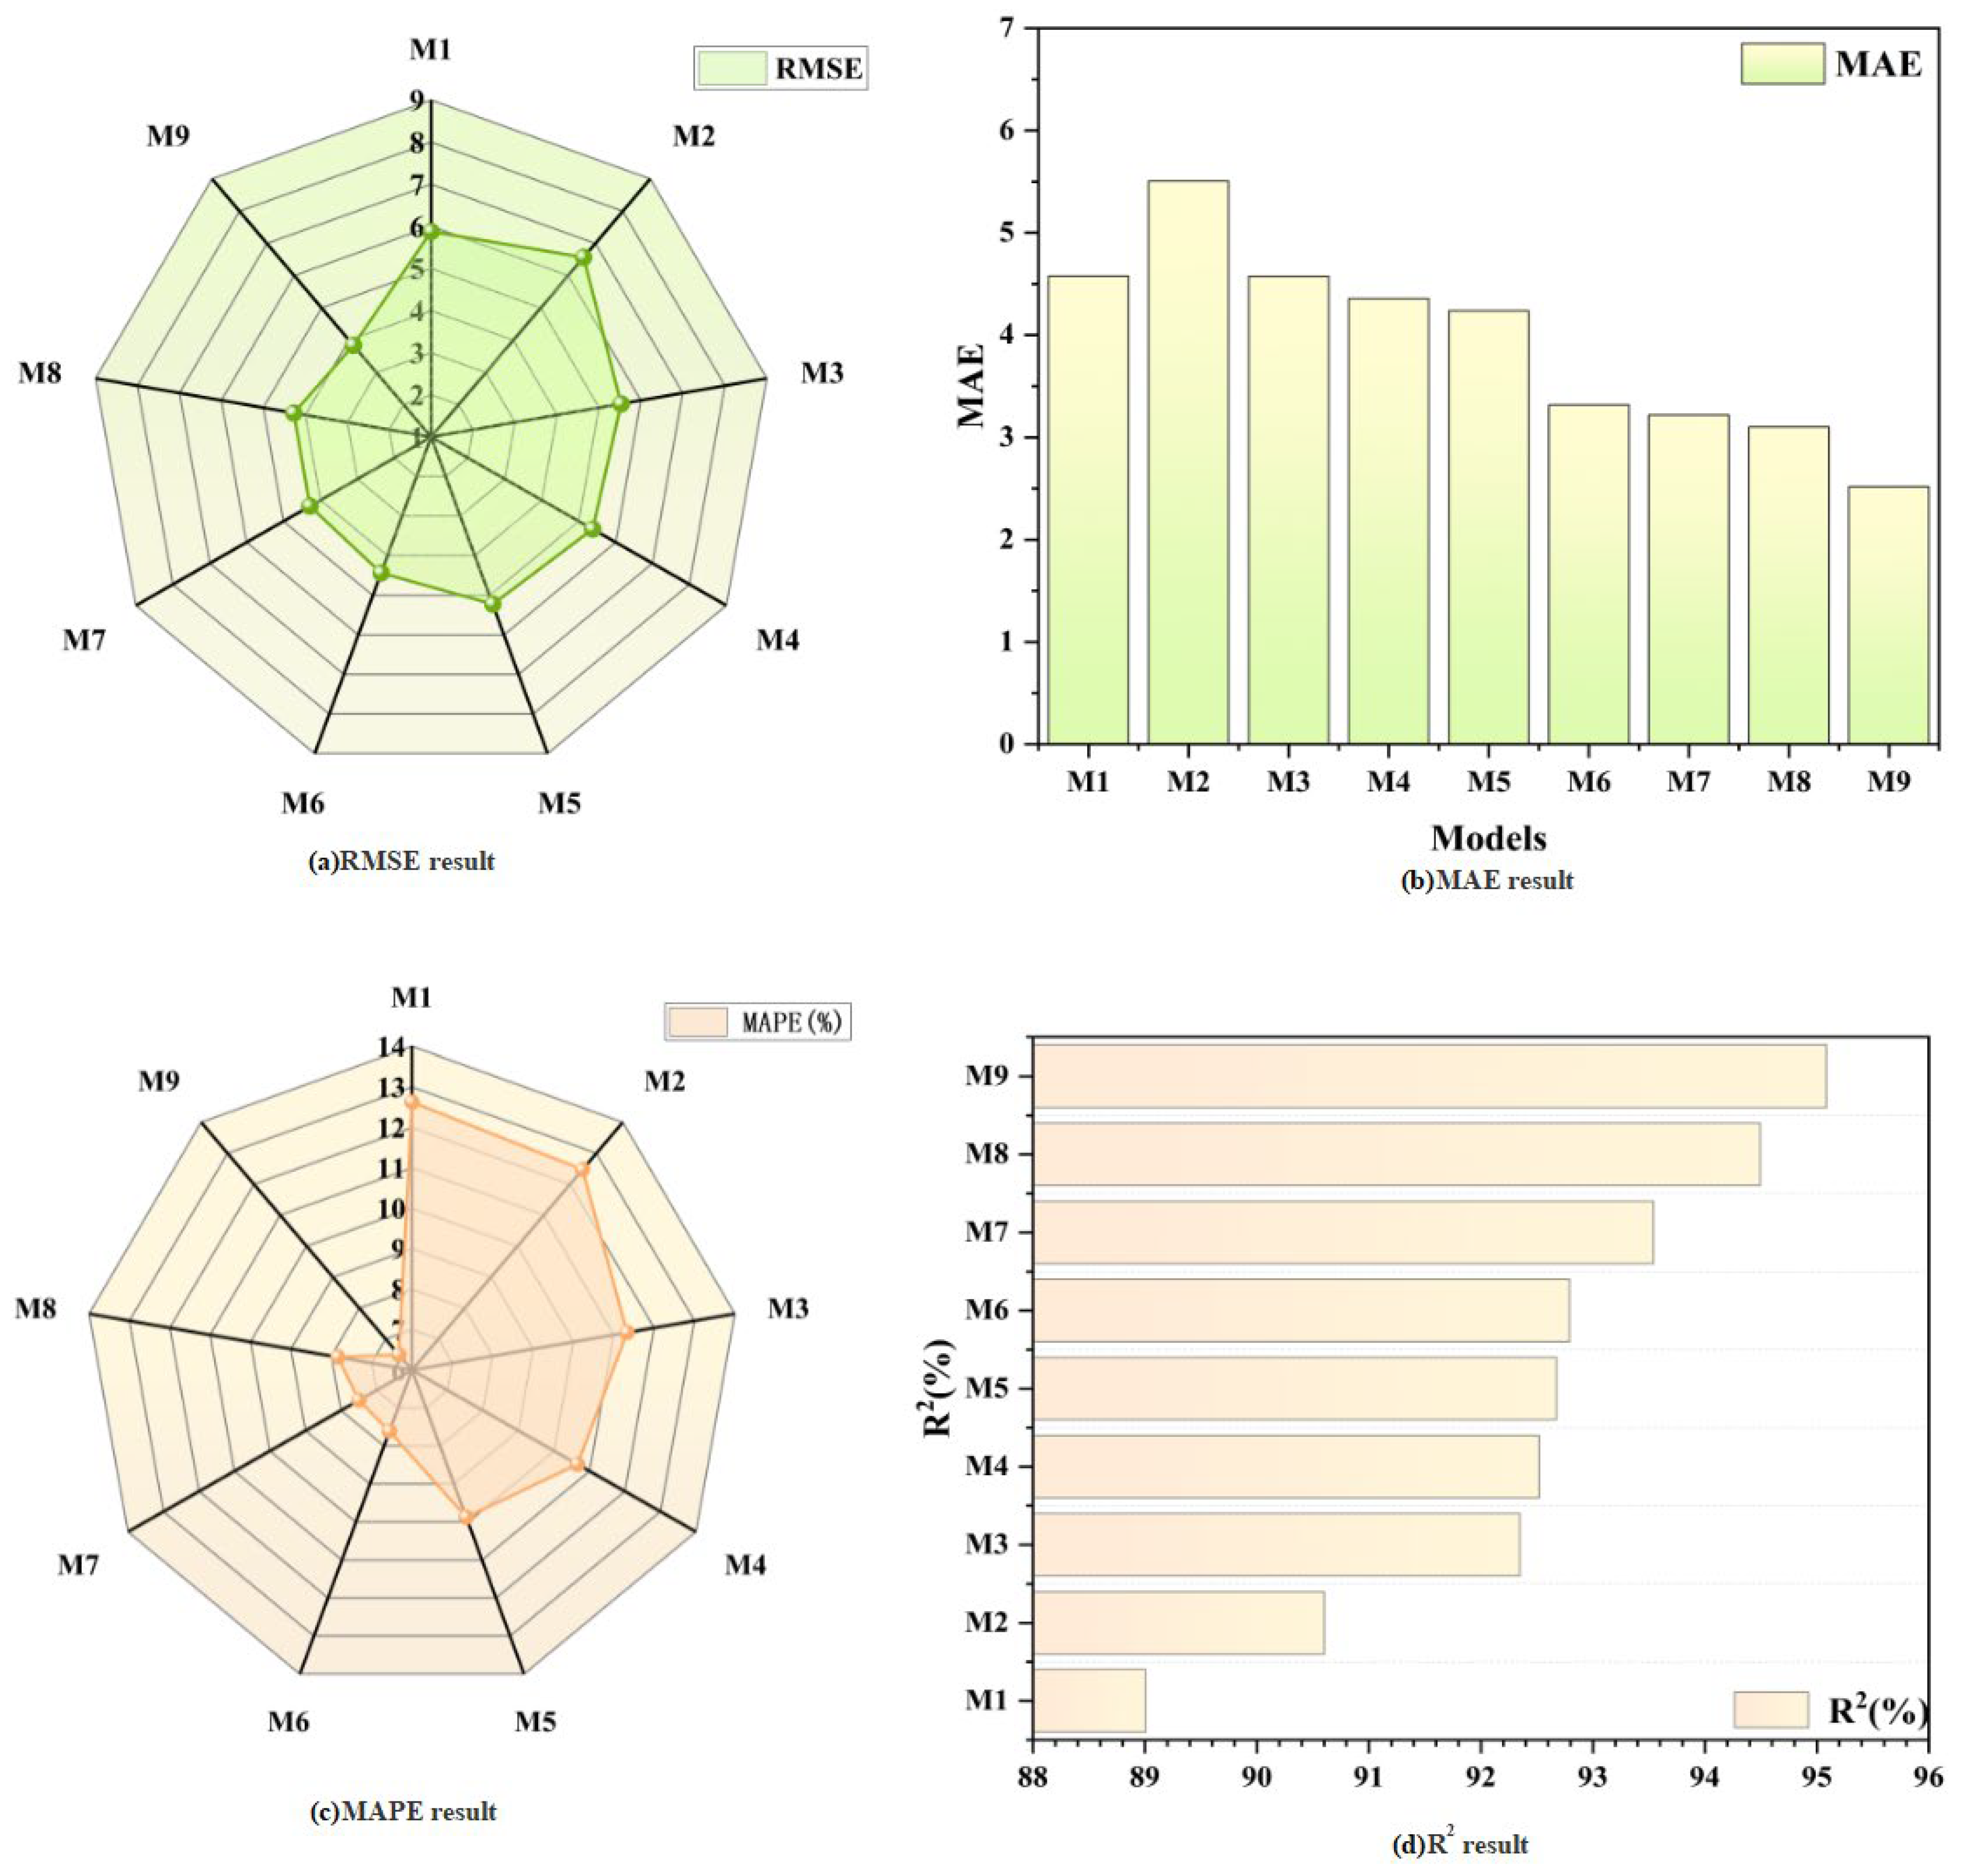
Table 4 summarizes the error metrics of the proposed and reference models for Dataset 1, and Figure 9 renders these comparisons in three graphical forms: bar chart, radar chart, and stacked chart. The results show that among the single benchmark models, RF achieves an RMSE of 7.6335, CNN 7.0683, and LSTM 6.3708. Compared to LSTM, BiLSTM demonstrates improved prediction accuracy, with its RMSE decreasing from 6.3708 to 6.2972. Furthermore, the BiLSTM model shows advantages in other metrics as well, with MAE, SMAPE and R2 values of 4.8226, 9.3374 and 92.52% respectively.
Table 4.
Comparison of error indicators for each model in Dataset 1.
Figure 9.
Prediction error metrics of different models for Dataset 1.
Building on the baseline models, four hybrid architectures were evaluated: CNN-BiLSTM, CNN-BiLSTM-Attention, VMD-CNN-ABiLSTM, and VMD-CNN-ABiLSTM-GCRA. All four models outperform the individual baselines. CNN-BiLSTM reduces the RMSE to 6.2393, while the addition of the attention mechanism increases R2 to 92.79%, indicating the benefit of adaptive feature weighting. Incorporating VMD further lowers the prediction errors by decomposing the original series into more regular components. With GCRA-based parameter optimization, VMD-CNN-ABiLSTM-GCRA achieves additional improvements in RMSE, MAE, SMAPE, and R2.
The proposed VMD-CNN-ABiLSTM-IGCRA model achieves the best performance across all evaluation metrics after IGCRA-based parameter optimization. It obtains an RMSE of 5.1042, an MAE of 3.7562, an SMAPE of 6.8278%, and an R2 of 95.08%. Relative to the corresponding model without IGCRA optimization, RMSE, MAE, and SMAPE decrease by 12.80%, 16.86%, and 11.63%, respectively, while R2 increases by 1.65 percentage points. These results demonstrate that IGCRA-based optimization improves both forecasting accuracy and goodness of fit.
5.1.2. Evaluation of Model Performance for Dataset 2
Figure 10 presents scatter plots of predicted versus observed values for Dataset 2, together with fitted regression lines and 95% prediction bands. Among all the models, the proposed VMD-CNN-ABiLSTM-IGCRA produces the narrowest prediction bands and the closest clustering of points around the fitted line, indicating superior stability and predictive accuracy.
Figure 10.
Linear regression plot between predicted and true values for Dataset 2.
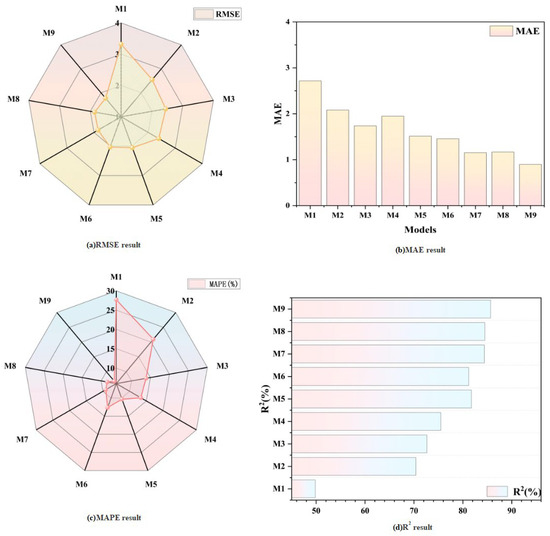
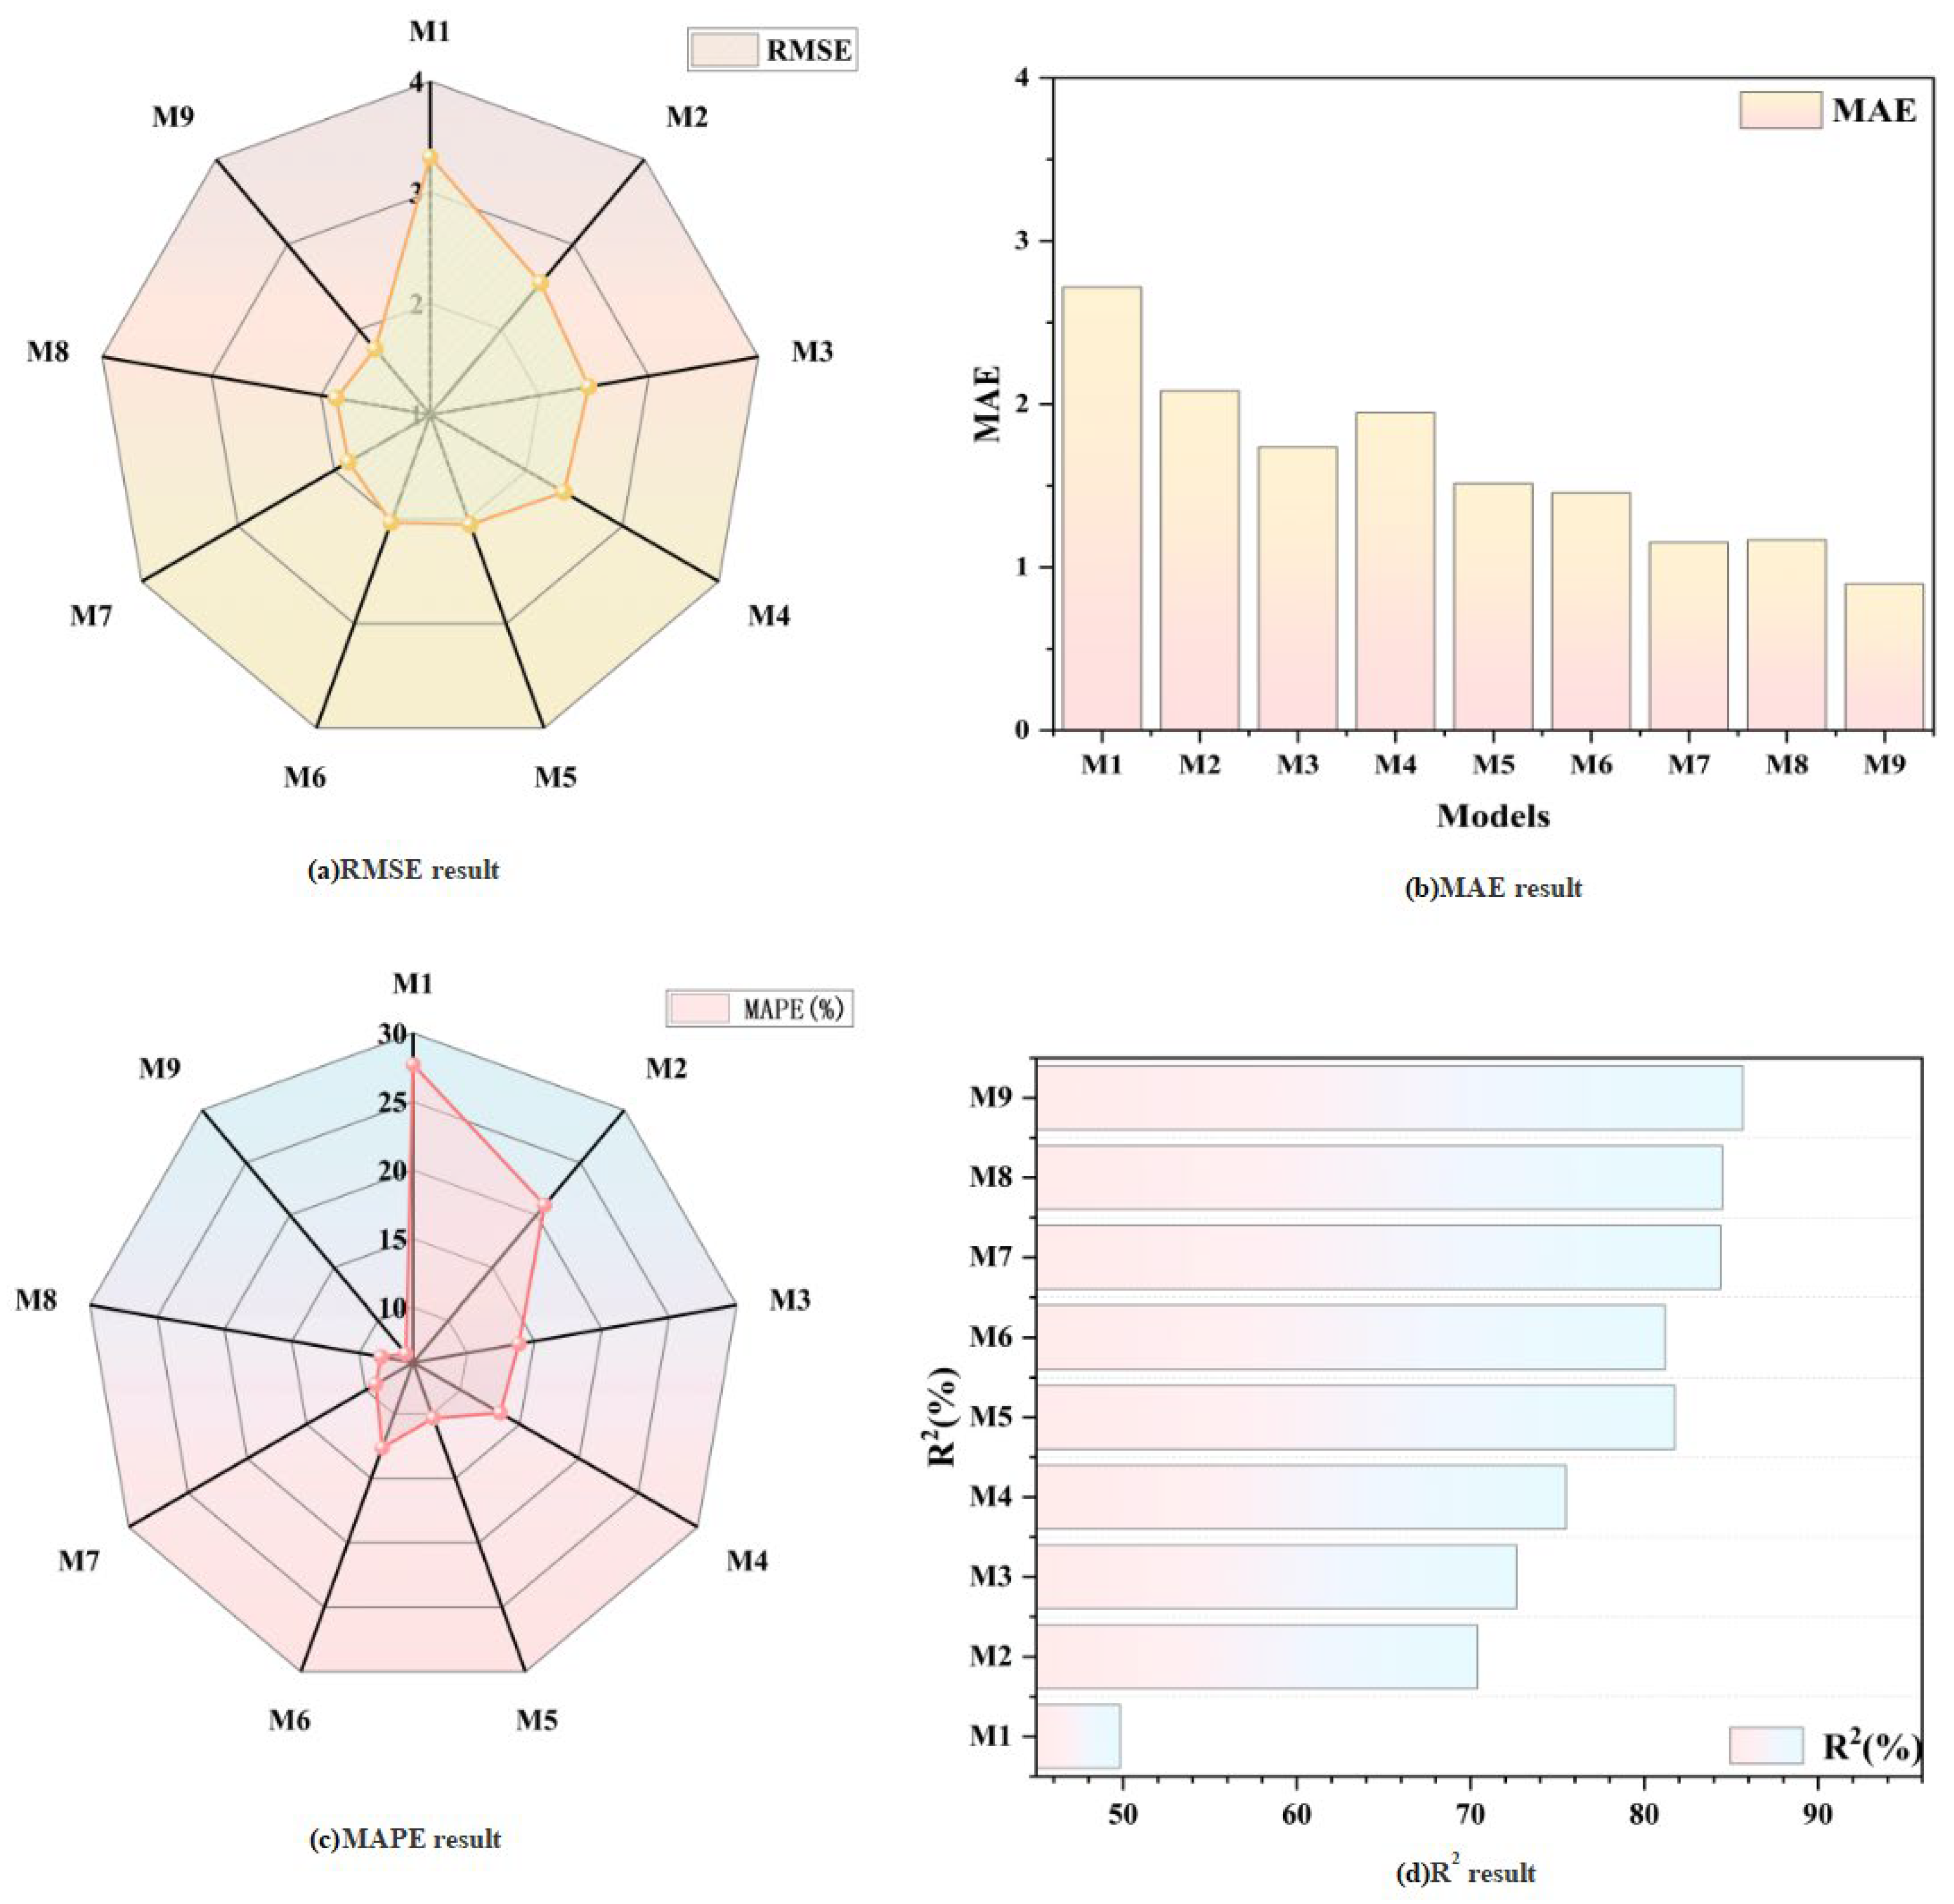
Table 5 presents the comparative prediction error metrics for Dataset 2, with Figure 11 providing the corresponding visualization. The proposed model obtains RMSE, MAE, SMAPE, and R2 values of 1.7719, 0.89626, 6.8291%, and 85.67%, respectively. Relative to the reported comparison models, the proposed configuration shows lower numerical errors and a higher R2 under the same case-study setting.
Table 5.
Comparison of error indicators for each model in Dataset 2.
Figure 11.
Comparative visualization of prediction error metrics across different models for Dataset 2.
5.1.3. Evaluation of Model Performance for Dataset 3
Figure 12 presents scatter plots of predicted versus observed values for Dataset 3, together with fitted regression lines and 95% prediction bands. The results show that the proposed VMD-CNN-ABiLSTM-IGCRA model yields the tightest prediction bands and the closest concentration of points around the fitted line, indicating the highest stability and predictive accuracy among the compared models.
Figure 12.
Linear regression analysis between predicted and observed values for Dataset 3.
Table 6 presents the comparative prediction error metrics for Dataset 3, with Figure 13 providing the corresponding visualization. The VMD-CNN-ABiLSTM-IGCRA model obtains RMSE = 3.8398, MAE = 2.5154, SMAPE = 6.4988%, and R2 = 92.99%. These values are numerically better than those of the reported comparison models under the same case-study setting.
Table 6.
Comparison of error indicators for each model in Dataset 3.
Figure 13.
Comparative analysis of prediction error metrics among benchmark models on Dataset 3.
Across Datasets 1–3, the proposed model obtains the best values among the compared methods for all four reported metrics. Its R2 values are 95.09%, 85.67%, and 92.99%, respectively; therefore, the results should be described as an R2 range of 85.67–95.09%, rather than as exceeding 92% for every dataset. Dataset 2 has the lowest R2 despite the smallest absolute RMSE and MAE, indicating that goodness-of-fit is more sensitive to the narrower variance and repeated values in that series. The combined use of scale-dependent errors and R2 is consequently necessary when comparing performance across stations.
5.2. Research on Power Output Characteristics of Different Charging Station Equipment
Based on the three prediction outputs, each pile-level load profile was multiplied by 10 to form a nominal ten-pile charging-station demand for the dispatch simulations. The resulting profiles are denoted Charging Stations 1, 2, and 3. WT, PV, GT, battery charge/discharge, and grid purchase/sale are coordinated using the equipment parameters in Table 7 and the time-of-use tariffs in Table 8. Four state-triggered cases are retained: Case 1 emphasizes environmental performance, Case 2 emphasizes electricity-price response, Case 3 emphasizes fluctuation suppression, and Case 4 coordinates economic and environmental objectives. This proportional scaling is used only to construct station-level simulation loads and does not alter the pile-level forecasting evaluation.
Table 7.
Equipment parameters.
Table 8.
Time-sharing electricity prices.
Case 1: Carbon-priority ecological scheduling;
Case 2: Price-driven scheduling;
Case 3: Fluctuation-stabilized scheduling;
Case 4: Economic–environmental balanced scheduling.
5.2.1. Research on Power Output Characteristics of Charging Station 1
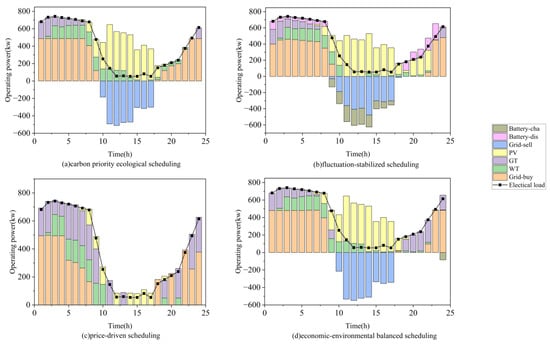
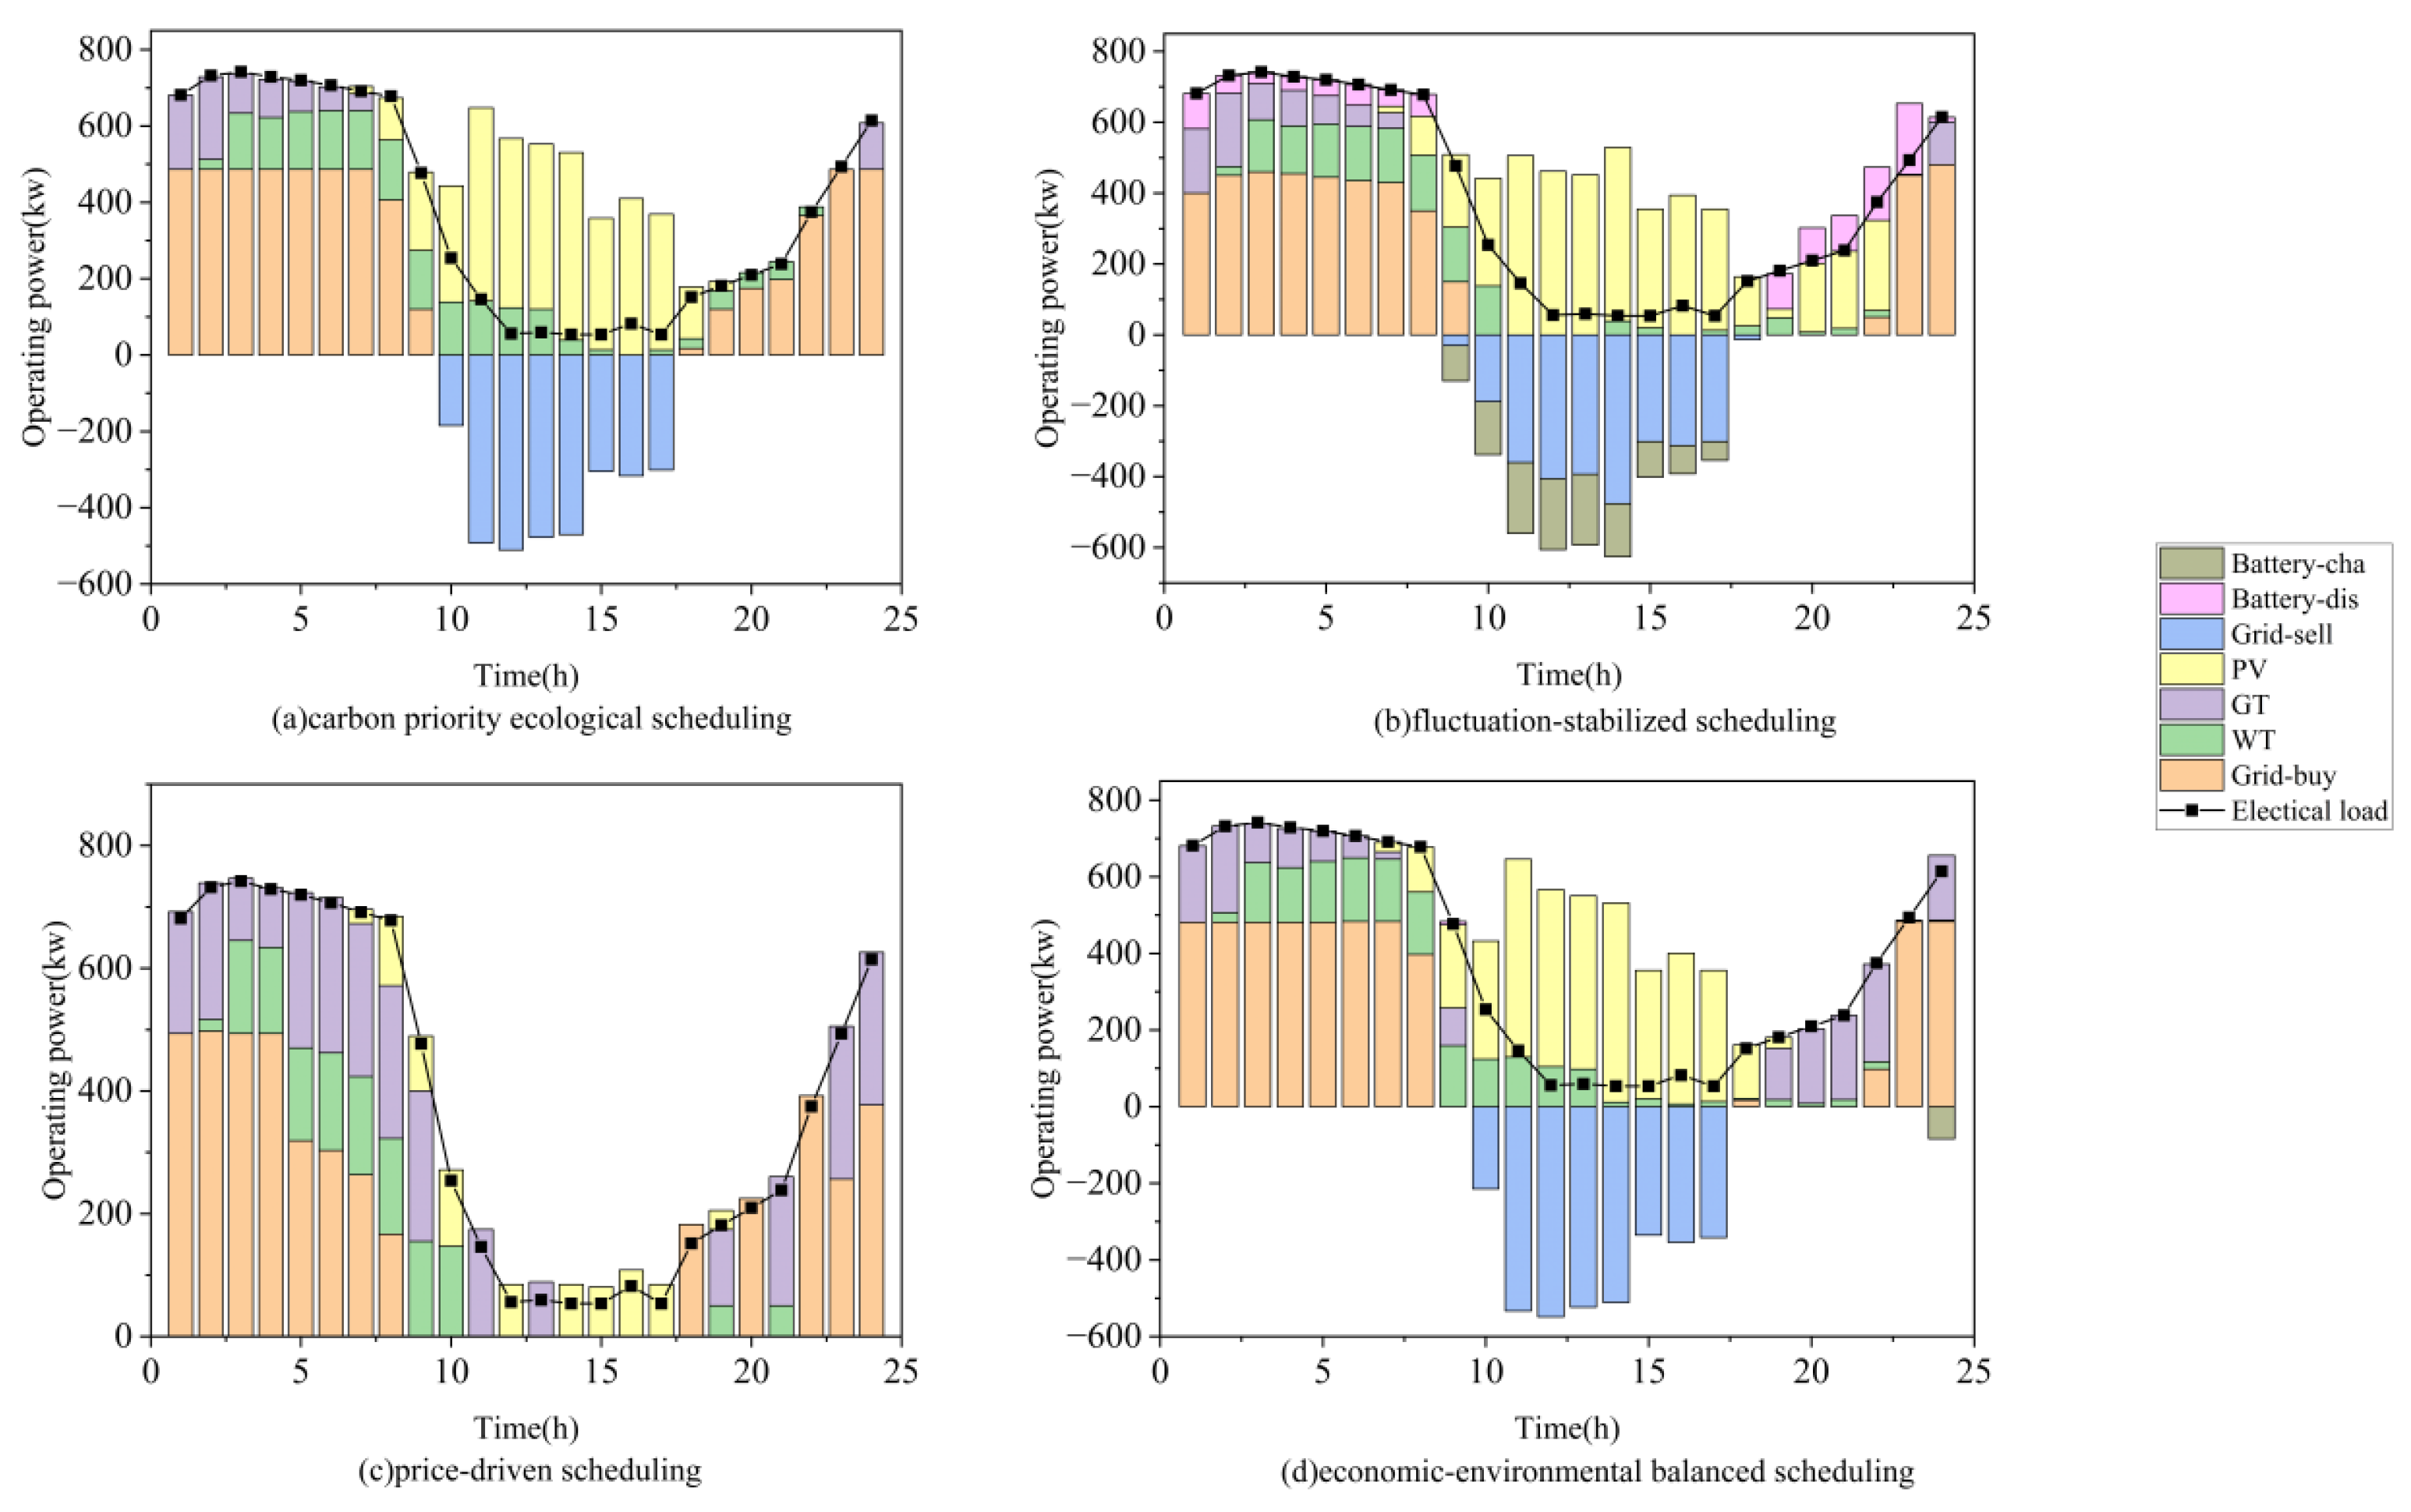
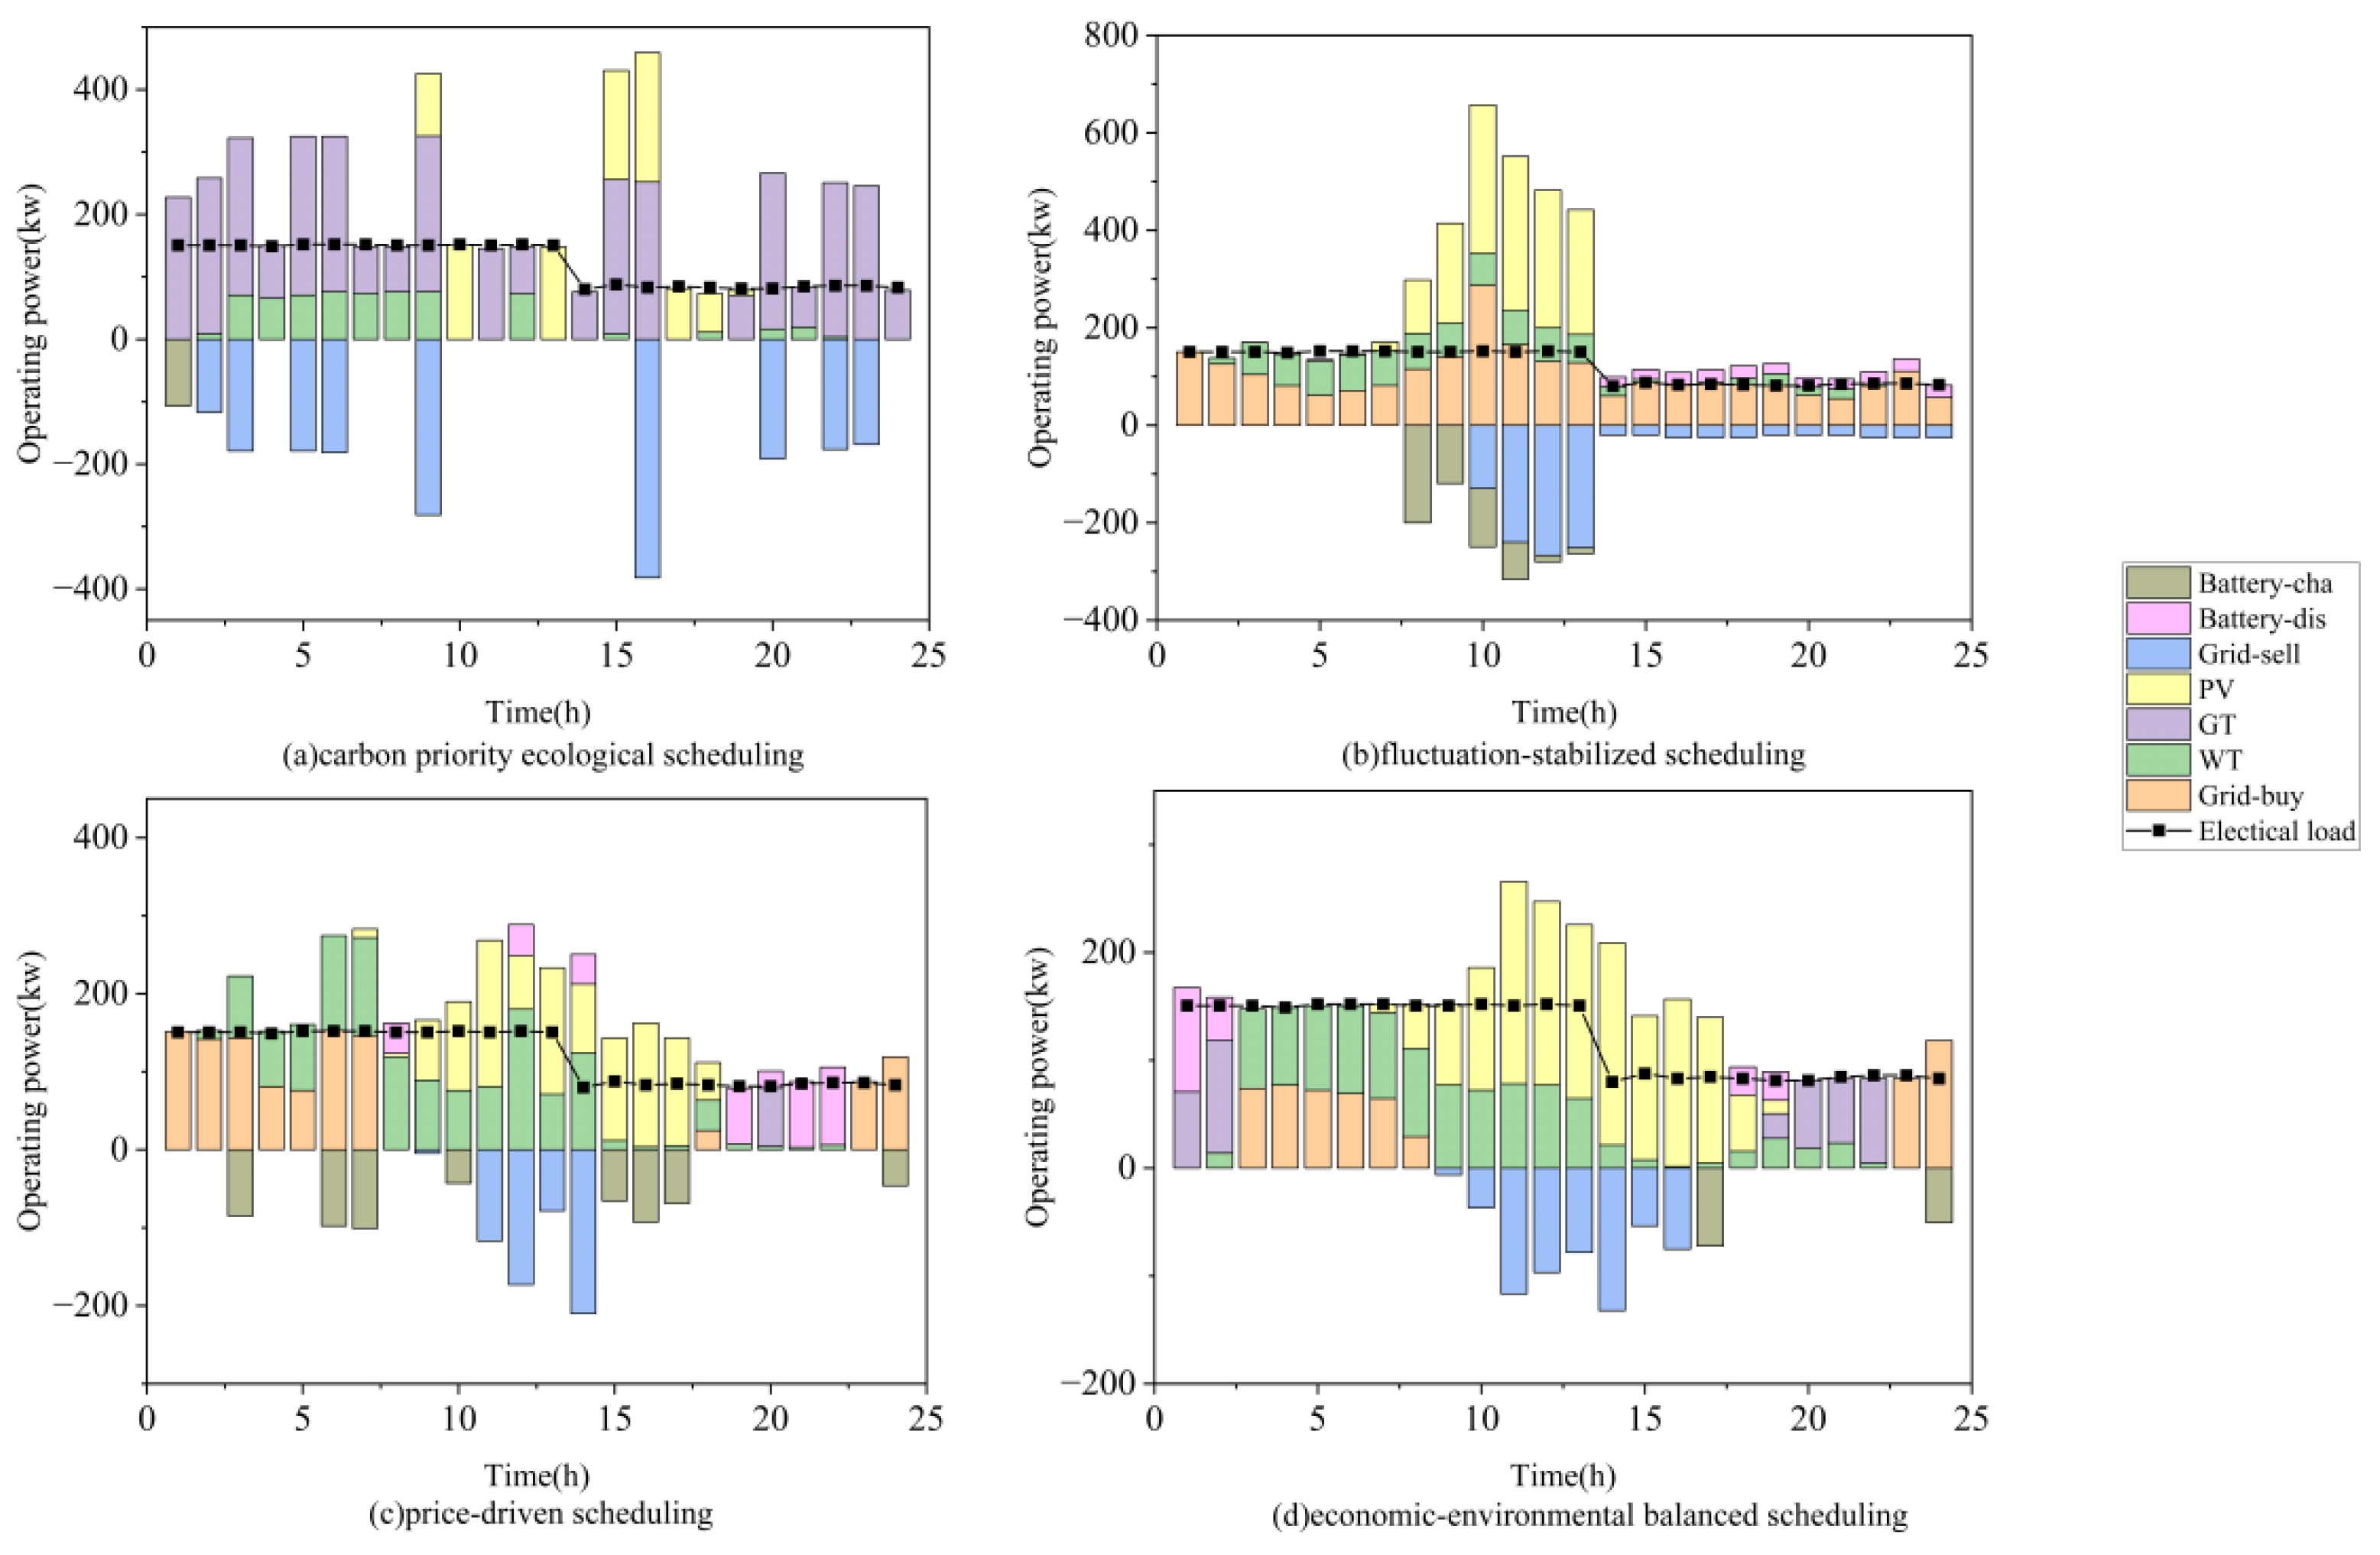
Figure 14 compares the four state-triggered power-balancing cases for Charging Station 1 using the Dataset 1 forecast scaled to a nominal ten-pile station. Case 1 (Carbon-Priority Ecological, Figure 14a) emphasizes environmental cost and renewable utilization. Case 2 (Price-Driven, Figure 14c) shifts grid purchases and dispatchable generation toward lower-price intervals. Case 3 (Fluctuation-Stabilized, Figure 14b) uses battery and gas-turbine flexibility to constrain grid exchange and suppress net-load variation. Case 4 (Economic–Environmental Balanced, Figure 14d) coordinates the two cost components while retaining the principal stability benefits. According to Table 9, Case 4 reduces total cost by 16.95% relative to Case 1.
Figure 14.
Power balance scenario based on Dataset 1 prediction results.
Table 9.
Cost comparison among four cases for Charging Station 1.
Table 9 quantifies the cost comparison. Case 4 has environmental, economic, and total costs of ¥3816.45, ¥3479.87, and ¥7296.32, respectively. Relative to Cases 1, 2, and 3, its total cost is reduced by 16.95%, 12.14%, and 17.08%, respectively. These values show that the balanced mode provides the lowest total cost for Charging Station 1 under the reported simulation conditions.
5.2.2. Research on Power Output Characteristics of Charging Station 2 Based on Prediction Results
Figure 15 compares the four state-triggered power-balancing cases for Charging Station 2 using the Dataset 2 forecast scaled to a nominal ten-pile station. Case 1 (Carbon-Priority Ecological, Figure 15a) prioritizes lower environmental cost and renewable supply. Case 2 (Price-Driven, Figure 15c) emphasizes tariff arbitrage. Case 3 (Fluctuation-Stabilized, Figure 15b) increases storage and gas-turbine support to moderate renewable variability. Case 4 (Economic–Environmental Balanced, Figure 15d) provides the lowest combined cost while preserving a coordinated operating profile. According to Table 10, Case 4 reduces total cost by 54.53% relative to Case 1.
Figure 15.
Power balance scenario based on Dataset 2 prediction results.
Table 10.
Cost comparison among four cases for Charging Station 2.
Table 10 quantifies the cost comparison. Case 4 has environmental, economic, and total costs of ¥1058.97, ¥714.56, and ¥1773.53, respectively. Relative to Cases 1, 2, and 3, its total cost is reduced by 54.53%, 22.61%, and 34.57%, respectively. The larger improvement for this station reflects the greater economic-cost reduction achieved under the balanced dispatch setting.
5.2.3. Research on Power Output Characteristics of Charging Station 3 Based on Prediction Results
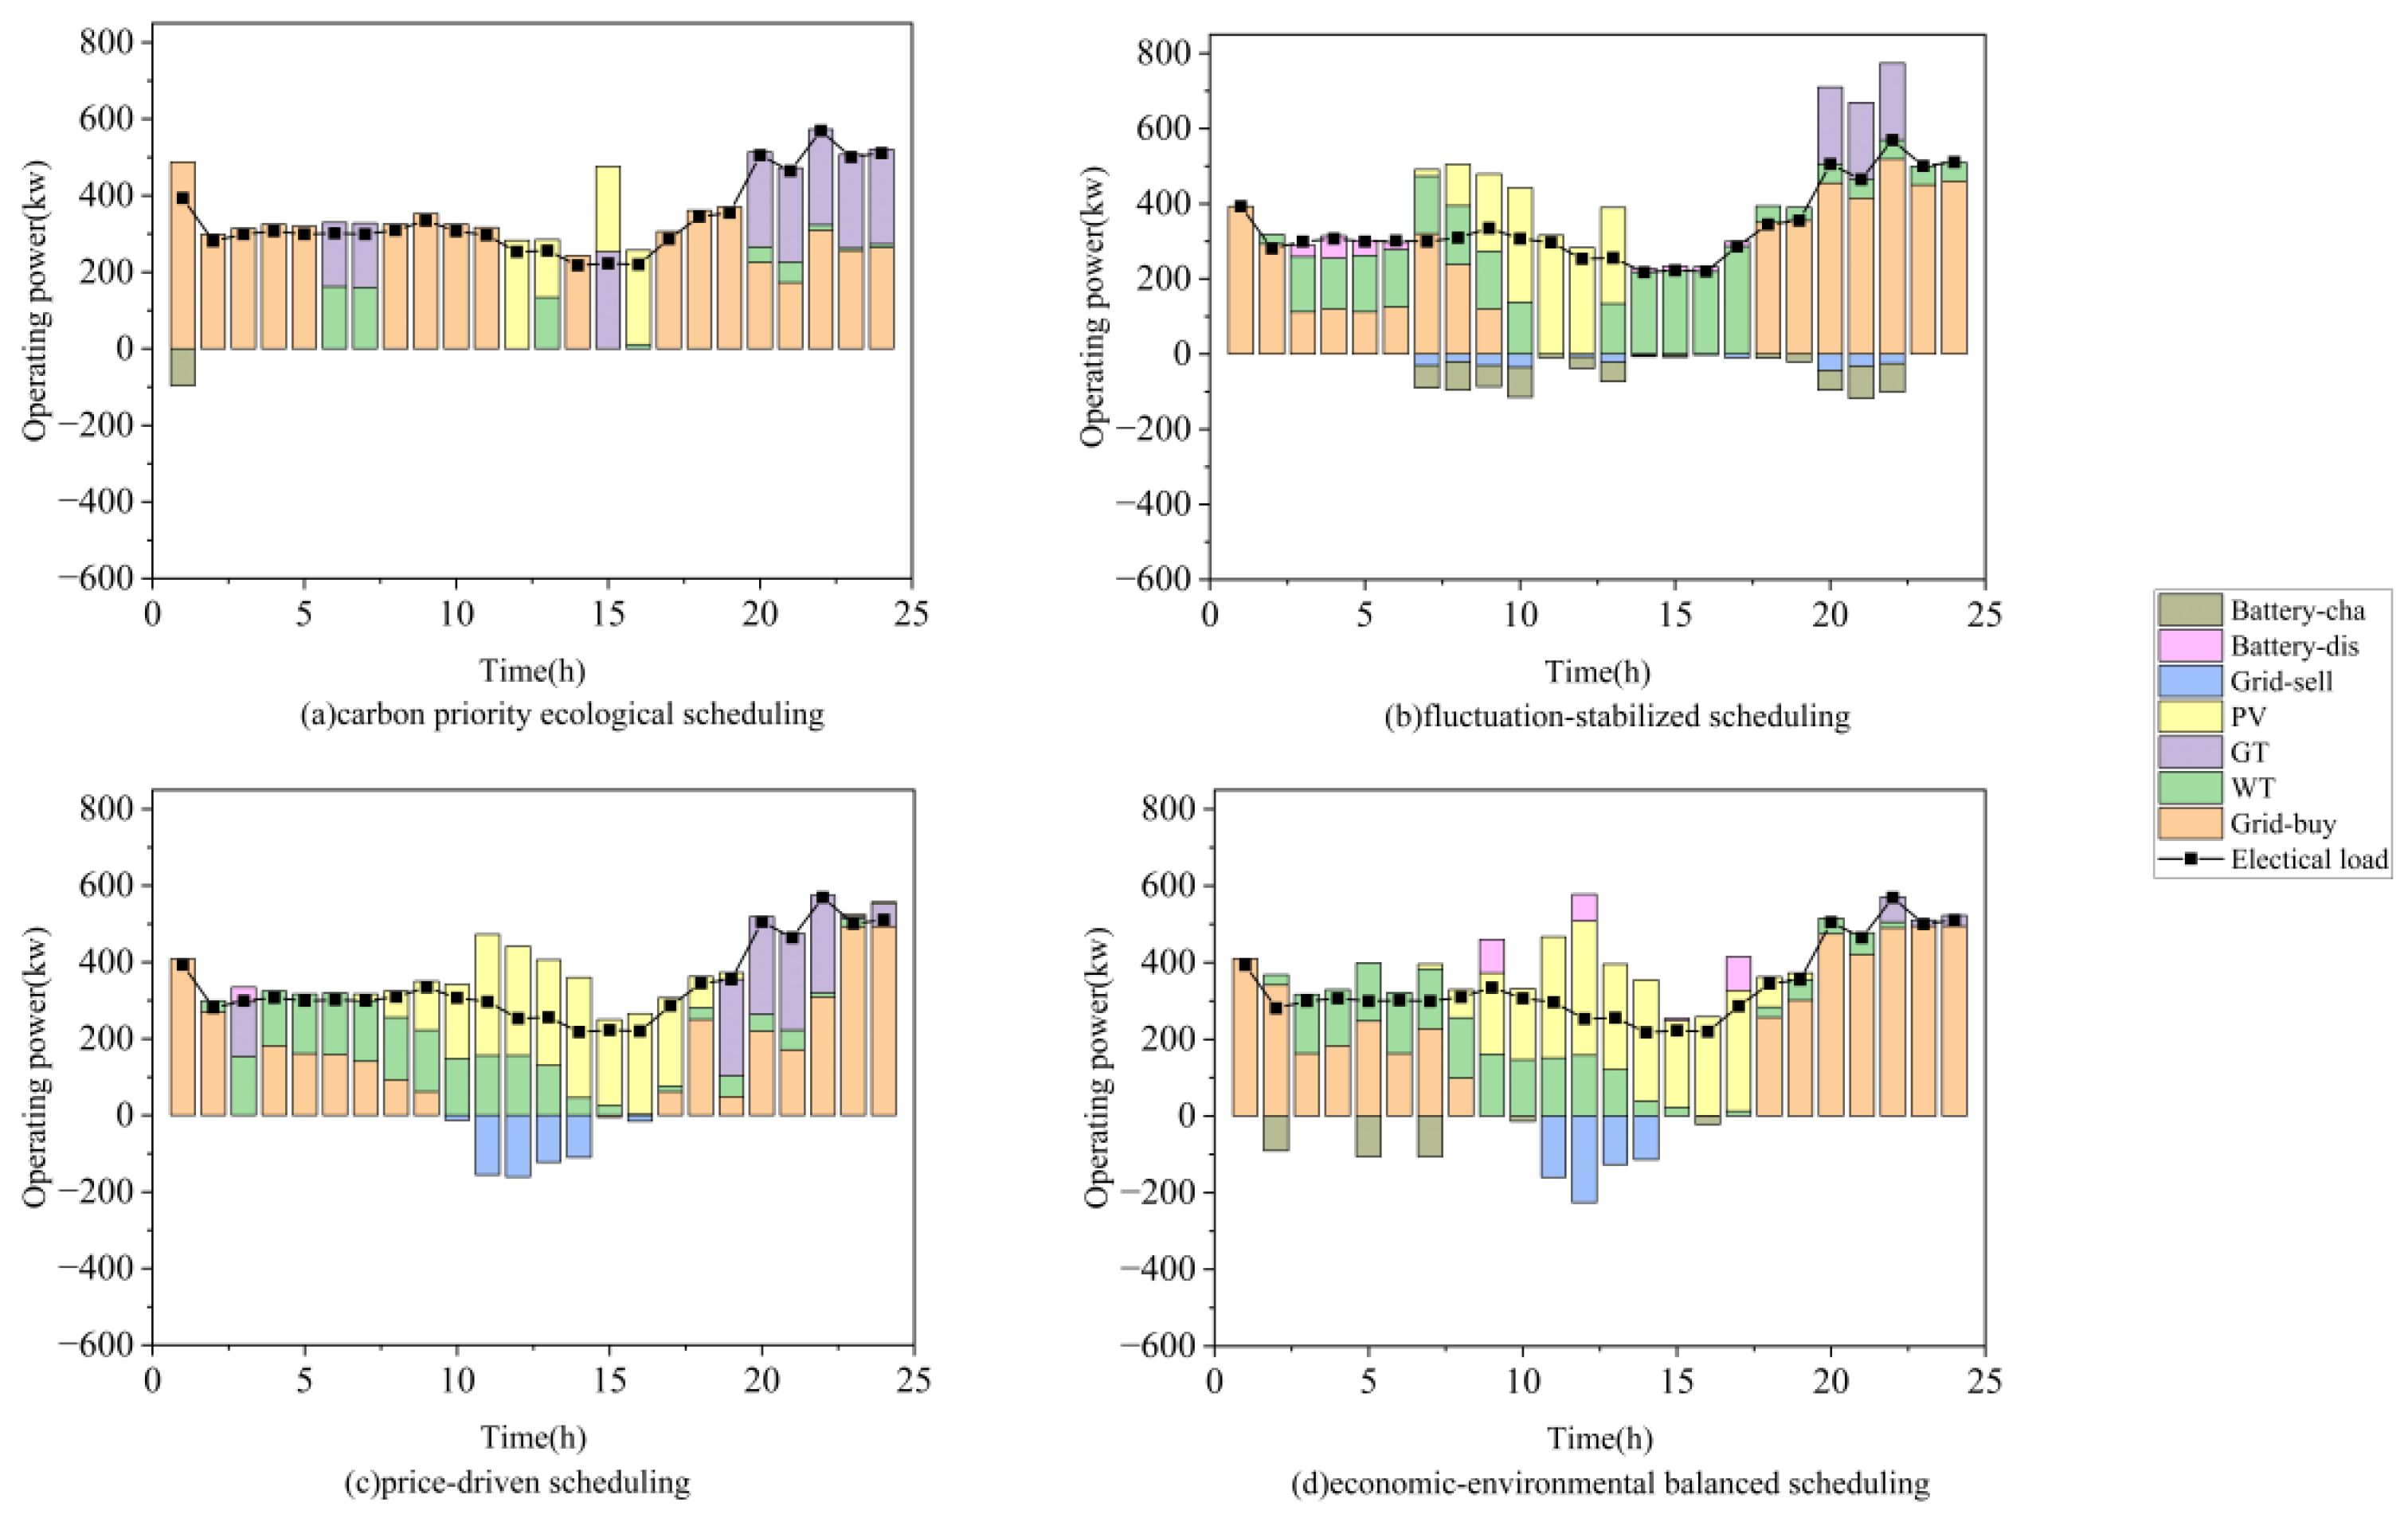
Figure 16 compares the four state-triggered power-balancing cases for Charging Station 3 using the Dataset 3 forecast scaled to a nominal ten-pile station. Case 1 (Carbon-Priority Ecological, Figure 16a) emphasizes renewable utilization and environmental cost. Case 2 (Price-Driven, Figure 16c) schedules grid exchange and dispatchable generation in response to the tariff profile. Case 3 (Fluctuation-Stabilized, Figure 16b) uses storage and reserve support to reduce output variation. Case 4 (Economic–Environmental Balanced, Figure 16d) coordinates these priorities and produces the lowest total cost. According to Table 11, Case 4 reduces total cost by 31.99% relative to Case 1.
Figure 16.
Power balance scenario based on Dataset 3 prediction results.
Table 11.
Cost comparison in three cases based on charging station 3.
Table 11 quantifies the cost comparison. Case 4 has environmental, economic, and total costs of ¥4486.026, ¥3479.867, and ¥7965.893, respectively. Relative to Cases 1, 2, and 3, its total cost is reduced by 31.99%, 11.23%, and 15.74%, respectively. The result confirms that the balanced mode provides the minimum combined cost for Charging Station 3 under the stated assumptions.
5.3. Limitations and Scope of Applicability
Several limitations define the scope of the present results. First, the three datasets contain only one month of hourly observations from three Shenzhen charging piles, so seasonal and cross-region generalization are not established. Second, K = 5 is a fixed VMD setting, and no systematic K-sensitivity analysis is reported. Third, the reported study uses a two-way chronological train-test protocol and does not report repeated multi-seed experiments, confidence intervals, or a full independent validation study; therefore, performance differences are interpreted numerically rather than statistically. Fourth, complete iteration-wise GCRA/IGCRA trajectories were not retained, so no quantitative claim is made regarding convergence speed or search efficiency. Fifth, the state-trigger thresholds are empirically calibrated from historical data, and their robustness under substantially different price, carbon, renewable, load, and battery regimes remains to be established. Finally, the dispatch study uses deterministic forecast inputs and does not quantify how forecasting errors propagate to cost, carbon, grid exchange, battery cycling, renewable curtailment, or feasibility. These issues are important directions for future multi-month, multi-station, uncertainty-aware validation.
6. Conclusions
This study develops an integrated forecasting-dispatch framework for EV-charging microgrids. The work combines VMD-CNN-ABiLSTM forecasting, an adaptively weighted GCRA variant for parameter tuning, and an interpretable state-triggered scheduling layer. The contribution is primarily the transparent coupling of these modules under a common microgrid model rather than a claim that the constituent forecasting or optimization techniques are individually new.
(1) Across the three reported datasets, the VMD-CNN-ABiLSTM-IGCRA configuration achieves the lowest reported forecasting errors among the compared models. Relative to the GCRA-based M8 model, the IGCRA-based M9 model reduces RMSE by approximately 11.43%, 4.73%, and 10.15% for Datasets 1–3, respectively; MAE by 17.08%, 23.19%, and 18.93%; and SMAPE by 7.44%, 18.59%, and 17.07%. The corresponding R2 values increase by approximately 0.59, 1.19, and 1.67 percentage points. These are numerical single-run differences under the reported configuration and are not presented as statistically significant or as evidence of faster convergence.
(2) The scheduling layer should be interpreted as a rule-based state-triggered decision mechanism rather than a formal structural causal model. Historical operating indicators activate carbon-priority, price-driven, fluctuation-stabilized, or balanced objective configurations; when several modes are eligible, the candidates are evaluated under common physical constraints and the feasible scalarized result with the lowest state-dependent objective is selected. The method therefore emphasizes interpretability and operational traceability, while sacrificing some of the autonomous adaptation available in policy-learning approaches.
(3) For the station-level dispatch simulations, Case 4 produces the lowest reported combined cost and reduces total cost relative to Case 1 by 16.95%, 54.53%, and 31.99% for Charging Stations 1–3, respectively. These results support the case-study value of linking forecast information to state-dependent dispatch priorities, but they should not be generalized beyond the reported stations and period without recalibrating the thresholds and validating the model under broader operating conditions.
(4) The present study is limited by the one-month observation window, the fixed VMD mode number, the absence of repeated random-seed statistics and retained convergence trajectories, and the lack of explicit forecast-error propagation and threshold-robustness analysis. Future work should therefore emphasize multi-month and multi-station validation, uncertainty-aware dispatch, systematic VMD and threshold sensitivity studies, repeated-run statistics, and direct equal-budget comparisons between GCRA, IGCRA, and learning-based optimization approaches.
Author Contributions
J.J. (corresponding author): Conceptualization, methodology design, supervision, project administration, manuscript review and editing. G.Z.: Model development, algorithm implementation, data curation, visualization, original draft preparation. X.M.: Data collection, preliminary analysis, model validation, results interpretation. Y.G.: System framework design, optimization strategy formulation, case study analysis, manuscript revision. K.W.: Experimental setup, simulation execution, performance evaluation. J.C.: Literature review, comparative analysis, introduction drafting, reference management. W.L.: Mathematical modeling, constraint formulation, objective function design. Z.D.: Algorithm optimization support, parameter tuning, code debugging. H.H.: Manuscript language polishing, technical proofreading, formatting coordination. X.X.: Software testing, sensitivity analysis, result verification, reproducibility assessment. B.L.: Resource coordination, data verification, manuscript review. All authors have read and agreed to the published version of the manuscript.
Funding
This research was supported by Huai’an Hongneng Group Co., Ltd. through the project “Research on a Portable Grounding-Grid Impedance Measurement Device with Branch-Current Phasor Measurement Capability” under Grant No. JC2025034.
Institutional Review Board Statement
This research employed operational data from public electric vehicle charging stations and did not involve human subjects, personal identifiers, or any form of participant interaction. No experiments on humans or animals were conducted, and no sensitive personal information was accessed. Consequently, no ethical approval was required by institutional review boards or ethics committees. All data were obtained through authorized technical collaboration agreements with charging infrastructure operators, ensuring compliance with relevant data privacy regulations.
Informed Consent Statement
Not applicable.
Data Availability Statement
The study uses one-month hourly charging-load records collected from three public charging piles in Shenzhen from 19 June to 18 July 2022, with 744 observations in each dataset. Due to commercial confidentiality agreements and data protection regulations governing operational charging infrastructure, the raw data cannot be publicly disseminated. However, de-identified processed data and the complete implementation code for the VMD-CNN-ABiLSTM-IGCRA framework are available from the corresponding author upon reasonable request. All model architecture parameters, hyperparameter configurations, and IGCRA specifications detailed in Table 2 and Table 3 are fully documented to ensure reproducibility.
Conflicts of Interest
Authors Guanjian Zhu, Yang Guo, Ke Wang, Jianyu Chen and Wei Li were employed by the company Huai’an Hongneng Group Co., Ltd. The authors declare that they have no competing financial, professional, or personal interests that could have influenced the interpretation or presentation of the research findings. This work was supported by Huai’an Hongneng Group Co., Ltd. through the project “Research on a Portable Grounding-Grid Impedance Measurement Device with Branch-Current Phasor Measurement Capability” under Grant No. JC2025034. The funder had no role in the study design, data collection, data analysis, interpretation of the results, preparation of the manuscript, or decision to submit the work for publication. The findings and conclusions presented in this study reflect the independent academic judgment of the authors.
References
- Nie, Z.; Song, H.; Lian, Y.; Shi, Z. Hierarchical optimization of SAC-driven speed planning and energy management in intelligent fuel cell hybrid vehicle platoons under complex traffic environments. Energy 2025, 334, 137625. [Google Scholar] [CrossRef] [Scilit]
- Li, Q.; Ru, Y.; Tao, Z.; Wu, Y. Uncertainty quantification of ensemble inverse analysis for rainfall-induced slope failure using mixture probabilistic programming. Eng. Geol. 2025, 357, 108341. [Google Scholar] [CrossRef] [Scilit]
- Fafoutellis, P.; Vlahogianni, E.I. A theory-informed multivariate causal framework for trustworthy short-term urban traffic forecasting. Transp. Res. Part C Emerg. Technol. 2025, 170, 104945. [Google Scholar] [CrossRef] [Scilit]
- Chaudhry, A.G.; Masoumi, H.; Dienel, H.-L.; Aslam, A.B.; Shahnaz, M.; Ahmad, M.; Hussain, M. Navigating urban mobility: Mobility attitudes and travel mode choices in Dubai and Lahore. Transp. Econ. Manag. 2025, 3, 245–268. [Google Scholar] [CrossRef] [Scilit]
- Yuan, Z.; Li, W.; Zhang, Q.; Liu, X.; Liu, Y.; Liu, J. A hybrid convolutional neural network for multi-station water level prediction: Enhancing navigation safety through spatial-temporal modelling. Environ. Model. Softw. 2025, 194, 106671. [Google Scholar] [CrossRef] [Scilit]
- Cavus, M.; Jiang, J.; Allahham, A. Deep multi-task forecasting of net-load and EV charging with a residual-normalised GRU in IoT-enabled microgrids. Energies 2026, 19, 311. [Google Scholar] [CrossRef] [Scilit]
- Genov, E.; De Cauwer, C.; Van Kriekinge, G.; Coosemans, T.; Messagie, M. Forecasting flexibility of charging of electric vehicles: Tree and cluster-based methods. Appl. Energy 2024, 353, 121969. [Google Scholar] [CrossRef] [Scilit]
- Cao, T.; Xu, Y.; Liu, G.; Tao, S.; Tang, W.; Sun, H. Feature-enhanced deep learning method for electric vehicle charging demand probabilistic forecasting of charging station. Appl. Energy 2024, 371, 123751. [Google Scholar] [CrossRef] [Scilit]
- Guler, Z.A.; Aksu, I.Ö.; Ghaemi, S. Hybrid VMD-LSTM-transformer model with Bayesian optimization for electricity load forecasting. Acad. Green Energy 2026, 3, 8123. [Google Scholar] [CrossRef] [Scilit]
- Liu, W.; Bai, Y.; Yue, X.; Wang, R.; Song, Q. A wind speed forecasting model based on RIME optimization based VMD and multi-headed self-attention-LSTM. Energy 2024, 294, 130726. [Google Scholar] [CrossRef] [Scilit]
- Romero-Barrera, A.J.; Sipols, A.E.; Paricio-Garcia, A.; Lopez-Carmona, M.A. Short-term wind power forecasting integrating wake effect modeling with variational mode decomposition enhanced deep learning architectures. Energy Convers. Manag. 2026, 348, 120738. [Google Scholar] [CrossRef] [Scilit]
- Zhang, X.; Bao, C.; Gao, B.; Zhang, L.; Song, Y.; Ma, Z.; Wan, J.; Li, L.; Wang, Y. The XGBoost wind speed prediction model based on VMD-LSTM error correction. Renew. Energy 2026, 267, 125708. [Google Scholar] [CrossRef] [Scilit]
- Jonasson, E.; Forsberg, S.; Jurasz, J.; Canales, F.A.; Temiz, I. Global techno-economic assessment of hybrid offshore wind, wave, and solar power. Appl. Energy 2026, 415, 127880. [Google Scholar] [CrossRef] [Scilit]
- Dong, Y.; Zhou, X.; Cao, X.; Jiang, J.; He, Y.; Yin, C. Optimal capacity configuration of wind-photovoltaic-storage hybrid systems based on improved chaotic evolution optimization algorithm. Sci. Rep. 2026, 16, 9990. [Google Scholar] [CrossRef] [Scilit]
- Awad, H.; Abu El-Nasr, N.S.M.; Mahmoud, H.; Abdalfatah, S. Techno-economic optimization of a grid-connected solar-wind-pumped hydro hybrid system for energy and desalination in Ras Ghareb, Egypt. Sci. Rep. 2026, 16, 14425. [Google Scholar] [CrossRef] [Scilit]
- Chafiq, M.; Benabbou, L.; Dagdougui, H.; Belhaj, I.; Bouzekri, H.; Berrado, A. Tailored performance evaluation framework for PV systems based on type and application. Renew. Energy 2026, 256, 124047. [Google Scholar] [CrossRef] [Scilit]
- Ma, L.; Xie, L.; Ye, J.; Bian, Y. Two-stage dispatching strategy for park-level integrated energy systems based on a master-slave-cooperative hybrid game model. Renew. Energy 2024, 232, 120971. [Google Scholar] [CrossRef] [Scilit]
- Zhang, K.; Chen, J.; Zhang, W.; Wei, M.; Lin, D. Coordinated optimal operation of multi-microgrids and distribution network considering shared energy storage multi-package leasing. J. Energy Storage 2026, 153, 121064. [Google Scholar] [CrossRef] [Scilit]
- Al-Rasheedi, M.; Al-Khayat, M. Assessing wind and solar energy complementarity using novel metrics based on residual load profiles. Energy 2025, 335, 138107. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Zhao, H.; Qi, Z.; Li, B. A two-stage low-carbon economic coordinated dispatching model for generation-load-storage resources considering flexible supply-demand balance. Appl. Energy 2024, 373, 123981. [Google Scholar] [CrossRef] [Scilit]
- Shen, H.; Zhang, H.; Xu, Y.; Chen, H.; Zhang, Z.; Li, W.; Su, X.; Xu, Y.; Zhu, Y. Two stage robust economic dispatching of microgrid considering uncertainty of wind, solar and electricity load along with carbon emission predicted by neural network model. Energy 2024, 300, 131571. [Google Scholar] [CrossRef] [Scilit]
- Gao, Y.; Li, S.; Xu, T.; Lakshminarayana, S.; Bu, S.; Gu, C.; Ai, Q. Distributed model predictive control strategy for multi-energy virtual power plant based on digital twin. IEEE Trans. Smart Grid 2025, 17, 1971–1984. [Google Scholar] [CrossRef] [Scilit]
- Pan, Y.; Ju, L.; Yang, S.; Guo, X.; Tan, Z. A multi-objective robust optimal dispatch and cost allocation model for microgrids-shared hybrid energy storage system considering flexible ramping capacity. Appl. Energy 2024, 369, 123565. [Google Scholar] [CrossRef] [Scilit]
- Yu, G.; Zhang, Z.; Cui, G.; Dong, Q.; Wang, S.; Li, X.; Shen, L.; Yan, H. Low-carbon economic dispatching strategy based on feasible region of cooperative interaction between wind-storage system and carbon capture power plant. Renew. Energy 2024, 228, 120706. [Google Scholar] [CrossRef] [Scilit]
- Li, S.; Guo, L.; Zhu, J.; Liu, M.; Chen, J.; Meng, Z. Short-term multi-step wind speed forecasting with multi-feature inputs using variational mode decomposition, a novel artificial intelligence network, and the Polar Lights Optimizer. Renew. Energy 2026, 256, 123965. [Google Scholar] [CrossRef] [Scilit]
- Dong, W.; Sun, H.; Hua, C.; Yang, H. Wind power generation system and its wind alignment regulation based on feedforward control. Energy Rep. 2025, 13, 2555–2564. [Google Scholar] [CrossRef] [Scilit]
- Lamani, L.; Leka, E.; Aliti, A.; Harizaj, M.; Kreka, K. A comparative analysis of LSTM and Bi-LSTM for forecasting energy consumption in Albania. TEM J. 2026, 15, 59–73. [Google Scholar] [CrossRef] [Scilit]
- Duan, Y.; Li, P.; Xia, J. Prediction and scheduling of multi-energy microgrid based on BiGRU self-attention mechanism and LQPSO. Glob. Energy Interconnect. 2024, 7, 347–361. [Google Scholar] [CrossRef] [Scilit]
- Shaikh, M.S.; Raj, S.; Zheng, G.; Xie, S.; Wang, C.; Dong, X.; Lin, Y.; Wang, C.; Junejo, N.U.R. Applications, classifications, and challenges: A comprehensive evaluation of recently developed metaheuristics for search and analysis. Artif. Intell. Rev. 2025, 58, 390. [Google Scholar] [CrossRef] [Scilit]
- Wu, X.; Chen, L.; Li, H.; Lopes, A.M.; Liu, C.; Chen, Y.; Chai, Y. Complex-order Darwinian particle swarm optimization. Expert Syst. Appl. 2026, 298, 129584. [Google Scholar] [CrossRef] [Scilit]
- Abir, A.R.; Nayeem, M.A.; Rahman, M.S.; Arefeen, A. GTG-ACO: Graph Transformer Guided Ant Colony Optimization for learning heuristics and pheromone dynamics for combinatorial optimization. Swarm Evol. Comput. 2025, 99, 102147. [Google Scholar] [CrossRef] [Scilit]
- Zhong, X.; Liang, B. Elite-based butterfly optimization algorithm and its application in speckle projection technique. Appl. Soft Comput. 2025, 169, 112561. [Google Scholar] [CrossRef] [Scilit]
- Piotrowski, A.P.; Piotrowska, A.E.; Napiorkowski, J.J. Experimental survey of L-SHADE and SHADE-based adaptive differential evolution algorithms. Swarm Evol. Comput. 2026, 101, 102286. [Google Scholar] [CrossRef] [Scilit]
- Dhiman, R.; Sood, M.; Thakur, J. A decade survey on exploration-exploitation trade-off in metaheuristics: A proposal for conceptual framework-based validation model. Comput. Sci. Rev. 2026, 61, 100944. [Google Scholar] [CrossRef] [Scilit]
- Zhuo, Y.; Yang, Q. An adaptive exploration-exploitation framework for success history based differential evolution. Appl. Soft Comput. 2026, 191, 114665. [Google Scholar] [CrossRef] [Scilit]
- Jerebic, J.; Ravber, M.; Mernik, L.; Mernik, M. On the exploration and exploitation capabilities of the Artificial Bee Colony Algorithm. Mathematics 2026, 14, 1406. [Google Scholar] [CrossRef] [Scilit]
- Fathollahi, A.; Gheisarnejad, M.; Boudjadar, J.; Homayounzadeh, M.; Khooban, M.-H. Optimal Design of Wireless Charging Electric Buses-Based Machine Learning: A Case Study of Nguyen-Dupuis Network. IEEE Trans. Veh. Technol. 2023, 72, 8449–8458. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.