


Abstract
Remotely operated vehicles (ROVs) suffer from severe navigation trajectory optimization problems in variable water-depth environments, as near-wall hydrodynamic effects cause synchronous scaling drift of added mass and damping coefficients. This parameter variation leads to obvious model mismatch in traditional fixed-gain controllers and seriously deteriorates ROV trajectory tracking accuracy. To address the scale-type parameter mismatch issue, this paper proposes an adaptive trajectory tracking control strategy combining forgetting-factor recursive least squares (RLS) online identification and periodic linear quadratic regulator (LQR) gain scheduling. A closed-loop coupling framework is established to estimate the discrete state-space matrices of ROVs via the RLS algorithm, and the optimal feedback gains are updated every 50 sampling steps to adapt to time-varying hydrodynamic characteristics. Three typical water-depth scenarios with different parameter mismatch degrees are set up for sinusoidal trajectory tracking simulations, adopting PID and fixed-parameter MPC as comparison methods. The results indicate that the proposed method maintains comparable steady-state performance with fixed-parameter MPC under nominal conditions, and reduces the two-dimensional trajectory RMSE by 8.4% and 57.4% under moderate and severe parameter mismatch conditions, respectively. A critical mismatch threshold of fixed-parameter MPC compensation capability is also determined. This study provides a feasible technical reference for high-precision adaptive motion control of ROVs in variable-depth water environments.
1. Introduction
Remotely operated vehicles (ROVs) can replace human operators in performing hazardous and complex underwater tasks, and have been widely applied in submarine pipeline inspection, underwater structural detection, deep-sea resource exploration, and marine scientific expeditions, forming a core component of marine engineering equipment systems [1,2,3]. As marine exploitation extends to wider depth ranges and broader operational areas, the depth span of ROV operations continues to expand, imposing increasingly stringent requirements on the tracking accuracy and operational adaptability of their motion control systems.
ROVs are typical multi-input multi-output (MIMO) nonlinear systems with strong coupling effects. Their dynamic characteristics are governed by hydrodynamic parameters including added mass and damping coefficients, the values of which are highly dependent on the surrounding fluid environment [4,5]. When ROVs operate across different water depths, variations in hydrostatic pressure, fluid density gradients, and flow field restructuring can induce significant drift in these hydrodynamic parameters. This leads to model mismatch in fixed-parameter controllers designed for nominal conditions, and consequently degrades tracking accuracy and control performance [6]. Accordingly, developing adaptive control methods that can accommodate parameter variations across multiple water depths is critical for improving the full-condition operational capability of ROVs.
Among existing ROV motion control studies, proportional–integral–derivative (PID) control has long been the dominant solution in industrial practice due to its simple structure and straightforward engineering implementation [7,8]. However, the gain parameters of PID controllers are typically tuned under specific operating conditions, which inherently limits their adaptability to time-varying model parameters. In scenarios with parameter drift induced by depth variations, issues such as amplitude attenuation and phase lag frequently arise [9].
To address the limitations of PID, model predictive control (MPC) has been widely investigated for ROV trajectory tracking applications. Benefiting from its strengths in multivariable coordination and explicit constraint handling, MPC achieves higher control accuracy than PID under nominal model conditions [10,11,12]. Nevertheless, the control performance of MPC relies heavily on the accuracy of the prediction model. When actual hydrodynamic parameters deviate from the modeled values, fixed-parameter MPC also suffers performance degradation due to model mismatch [13]. Existing research indicates that relying solely on the robust design of the controller itself cannot fully compensate for systematic model mismatch caused by large-scale parameter drift. Improving the real-time consistency between the prediction model and the actual system is the core approach to resolving performance degradation under varying water depths.
To tackle time-varying model parameters, adaptive control and online system identification methods have been gradually introduced into ROV control systems. Among these, the recursive least squares (RLS) algorithm has become a classic approach for online identification due to its high computational efficiency, fast convergence, and ease of engineering implementation [14,15]. The forgetting-factor RLS algorithm can effectively track slowly varying system parameters by assigning higher weights to recent data, and has been validated in applications including ship dynamic identification and underwater vehicle parameter estimation [16]. Integrating online identification results with an optimal control law to construct a control framework with adaptive parameter updating provides a feasible solution to the model mismatch problem under varying water depths.
Despite the advances made in relevant research, three key research gaps remain in the field of ROV adaptive control under varying water-depth conditions. First, most existing studies focus on random parameter perturbations or additive external disturbances, while systematic quantitative assessments of tracking optimization performance under structured proportional scaling mismatch caused by depth-varying hydrodynamics remain inadequate. Second, the intrinsic mechanism of “inertia-damping coordinated scaling” model mismatch has not been thoroughly analyzed from the perspective of state-space matrix transformation, and its impact on the performance boundary of fixed-parameter controllers has yet to be systematically revealed. Third, the closed-loop coupling between online identification and control law updating remains insufficient for depth-varying navigation optimization scenarios. Most existing identification methods are applied to offline parameter calibration or open-loop correction, and few studies have developed a closed-loop adaptive optimization framework with periodic gain scheduling based on real-time identified state-space matrices.
To address the aforementioned research gaps, this paper makes three specific contributions:
It reveals, from the perspective of state-space matrix transformation, that the inverse scaling of the control input matrix, rather than drift of the system state matrix, is the dominant mechanism of tracking performance degradation under depth-induced “inertia-damping coordinated scaling” mismatch.
It constructs a closed-loop adaptive trajectory tracking framework coupling forgetting-factor recursive least squares (RLS) online identification with periodic linear quadratic regulator (LQR) gain scheduling, where the directly identified discrete state-space matrices are used for gain updating without intermediate inverse derivation of hydrodynamic parameters.
It quantitatively determines the critical mismatch threshold of fixed-parameter model predictive control (MPC) and verifies the online adaptation capability under continuous depth transition scenarios.
The remainder of this paper is organized as follows. Section 2 establishes the ROV dynamic model and elaborates the three controller design schemes. Section 3 presents the multi-depth simulation experiments and corresponding result analysis. Section 4 discusses the performance mechanism and engineering implications of the proposed method. Section 5 concludes the paper and outlines future research directions.
2. Materials and Methods
In this section, a 6-degree-of-freedom (6-DOF) mathematical model of the ROV is established based on rigid-body dynamics and fluid mechanics theory, and the hydrodynamic parameter scaling mechanism under varying water depths is derived. On this basis, three control schemes (PID, fixed-parameter MPC, and the proposed RLS-based adaptive controller) are sequentially designed for comparative analysis.
2.1. ROV System Modeling
2.1.1. Coordinate Frame Definition
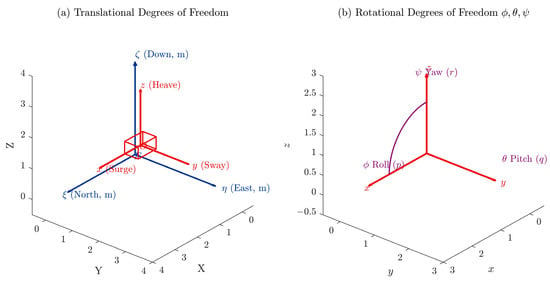
To accurately describe the spatial motion of the ROV, an earth-fixed inertial frame () and a body-fixed frame () are established, both satisfying the right-hand rule:
Earth-fixed inertial frame (): The origin E is located at a fixed point on the sea surface; the Eξ axis points horizontally toward the geographic north; the Eη axis points horizontally toward the geographic east; the Eζ axis points vertically downward, aligned with the direction of gravity.
Body-fixed frame (): The origin O is located at the center of gravity of the ROV; the Ox axis points forward along the longitudinal axis of the vehicle; the Oy axis points to starboard along the transverse axis; the Oz axis points downward along the vertical axis.
The spatial motion of the ROV comprises six degrees of freedom. The kinematic variables are defined as follows:
Position vector (in the inertial frame): , where denotes the surge displacement, the sway displacement, the heave displacement, the roll angle, the pitch angle, and the yaw angle.
Velocity vector (in the body-fixed frame): , where denotes the surge velocity, the sway velocity, the heave velocity, the roll angular velocity, the pitch angular velocity, and the yaw angular velocity.
The two coordinate frames are related through the attitude angles (roll , pitch , and yaw ) and the corresponding coordinate transformation matrix, enabling the conversion of ROV motion states between different coordinate frames, as shown in Figure 1.
Figure 1.
Definition of ROV coordinate frames and schematic diagram of the six degrees of freedom.
2.1.2. Kinematic Equations
The coordinate transformation between the pose rate in the inertial frame and the velocity in the body-fixed frame is expressed as follows:
where is the attitude angle subvector, and is the 6 × 6 Jacobian transformation matrix, which possesses a block diagonal structure:
is the transformation matrix that maps the body-fixed linear velocities to the derivatives of the inertial-frame position coordinates; is the transformation matrix that maps the body-fixed angular velocities to the derivatives of the Euler angles. Together, the two submatrices accomplish the mapping of ROV motion states between the body-fixed frame and the inertial frame.
The translational transformation submatrix is given as:
The rotational transformation submatrix is given as:
For ROV inspection operations, the attitude angles are maintained at small magnitudes, typically satisfying , , under which the small-angle approximations , hold. Substituting these approximations into yields ; similarly, . Consequently, the overall Jacobian matrix satisfies . It is quantitatively evaluated that at the maximum deviation of , the position conversion error introduced by the Jacobian approximation is less than 1%. In low-speed horizontal-plane trajectory tracking scenarios, the error induced by this simplification is negligible. Therefore, this simplified condition is uniformly adopted in the subsequent controller design.
2.1.3. Dynamic Equations
Within the Newton–Euler framework, the 6-DOF dynamic equations of the ROV in the body-fixed frame are formulated as follows:
The physical meanings of the matrices and vectors involved are as follows:
The system inertia matrix is composed of the superposition of the rigid-body mass matrix and the added-mass matrix:
where is the rigid-body mass-inertia matrix of the ROV, and is the fluid added-mass matrix, which originates from the equivalent inertia induced by the simultaneous motion of the surrounding water when the ROV undergoes accelerated motion. As water depth increases and near-wall flow confinement intensifies, the range of fluid disturbance expands, leading to a corresponding increase in the added mass. This mechanism constitutes the core source of the model mismatch under varying water-depth conditions in this study.
The Coriolis/centripetal matrix satisfies the skew-symmetric property , which guarantees the positive definiteness of the system kinetic energy dissipation and serves as the theoretical foundation for the stability analysis of the adaptive closed-loop system in the subsequent sections. This matrix is determined solely by the ROV geometry and mass distribution, and is minimally affected by water-depth variations in terms of flow-field coupling coefficients. Therefore, nominal values are uniformly adopted across the three simulation conditions. It is quantitatively verified that the resultant Coriolis force accounts for less than 4.5% of the total dynamic load on the system; hence, the modeling error introduced by fixing this matrix is negligible. The damping matrix comprises both linear and nonlinear damping components:
where is the linear viscous damping matrix, and is the nonlinear quadratic damping matrix associated with the square of velocity, which is typically expressed as follows:
The complete expression of the restoring moment due to gravity and buoyancy is jointly determined by the offsets of the center of gravity and the center of buoyancy, as well as the buoyancy deficit . In the simulations of this study, . Since the vertical displacement variation is extremely small during horizontal-plane operations, the restoring moment amplitude is far below the propeller output thrust and can thus be neglected as a bounded small perturbation. For future applications involving high-precision vertical control at large depths, this term can be incorporated into the system disturbance term. The unified control input denotes the resultant force and resultant moment vector generated by the six thrusters.
2.1.4. Linear Simplification and Discrete State-Space Model
The damping matrix consists of the linear viscous damping matrix and the quadratic nonlinear damping matrix . In this study, the maximum operational speed of the ROV satisfies . A quantitative comparison of the damping force magnitudes reveals that the linear damping force is significantly larger than the quadratic damping force, with the nonlinear damping term accounting for less than 5% of the total load. Therefore, under low-speed conditions, the nonlinear damping term can be entirely neglected, retaining only the linear damping . Meanwhile, the Coriolis matrix can be approximated as a constant matrix in the vicinity of the operating point. Based on the above assumptions, Equation (7) is linearized at the equilibrium point ():
where and . Rearranging the above yields the continuous-time state-space equation:
namely,
2.1.5. Discrete-Time State-Space Model
Considering the implementation characteristics of digital control systems, the forward Euler method is adopted to discretize the continuous-time state-space model. With the sampling period set to , which satisfies both the system bandwidth requirements and the real-time computation constraints, the discrete-time state-space model is obtained as follows:
where the discrete-time system matrix is given by the following:
For control problems that focus solely on velocity tracking, the full-order model can be reduced to a lower-order discrete model with as the state:
2.1.6. Model Simplification and Simulation Parameters
Considering the low-speed operational characteristics of the ROV, the following reasonable simplifying assumptions are made:
- (1)
- The ROV is treated as a rigid body, with high-frequency elastic vibrations neglected;
- (2)
- The thruster outputs are linearized under low-speed conditions.
The core parameters of the simulation model are listed in Table 1 (corresponding to the 3 m water-depth condition):
Table 1.
Core parameters of the ROV simulation model.
On this basis, considering the scaling effect of water depth on the hydrodynamic parameters, a comparison of the core hydrodynamic parameters under the three operating conditions is presented in Table 2. The rigid-body parameters and thruster parameters are independent of water depth and remain unchanged at their nominal values across all three conditions.
Table 2.
Core hydrodynamic parameters under different water depths.
The physical basis for the parameter settings in this study is as follows. The fixed parameters, including rigid-body mass and added mass, are referenced from publicly available literature on similar small open-frame ROVs. The increase in water depth leads to variations in fluid density, as well as enhanced near-wall effects and modified free-surface effects, which simultaneously amplify both the added mass and the linear damping coefficients, resulting in the “inertia-damping coordinated scaling” type of model mismatch [6,7]. The above parameters have been validated through Simulink simulations, in which the ROV converges to a stable hovering state under disturbance-free conditions, thereby confirming the rationality of the parameter configurations.
2.1.7. Water-Depth Dependence of Hydrodynamic Parameters and Modeling Errors
The aforementioned nominal model parameters exhibit the highest modeling accuracy only under the 3 m shallow-water condition. When the operational water depth of the ROV varies, the hydrodynamic parameters, including added mass and linear damping, deviate from their nominal values due to a combination of factors such as increased hydrostatic pressure, variations in fluid density gradients, reconstruction of the pressure distribution around the vehicle hull, and alterations in near-wall effects. Such deviations consequently give rise to model mismatch.
A change in the operational water depth of the ROV simultaneously induces two types of flow-field variations: first, the increase in hydrostatic pressure leads to a slight rise in the equivalent density of the surrounding water; second, the reduced distances between the vehicle hull and the seabed as well as the free surface substantially enhance the constraining effect of near-wall boundaries. These two effects jointly expand the volume of water entrained during the ROV’s accelerated motion, causing the fluid added-mass matrix and the linear viscous damping matrix to increase synchronously, thereby giving rise to a parameter drift pattern characterized by the proportional scaling of inertia and damping coefficients [17,18].
Define the water-depth scaling factor g for hydrodynamic parameters. The total system inertia matrix consists of a constant rigid-body part and a depth-dependent added-mass part:
where is the rigid-body mass-inertia matrix invariant with water depth, and is the added-mass matrix at the nominal depth of 3 m.
The linear damping matrix follows the same proportional scaling rule, as both originate from the same near-wall flow confinement effect:
where is the linear viscous damping matrix at 3 m depth. For the multi-water-depth model mismatch simulations in this study, a unified setting of identical scaling factors for added mass and damping is adopted, i.e., both are scaled simultaneously by the same factor g. The corresponding scaling coefficients for the 3 m, 5 m, and 10 m conditions are , respectively.
The Coriolis matrix is determined solely by the ROV geometry and rigid-body mass distribution, with the near-wall flow confinement and fluid density exerting negligible influence on the coupling terms. Quantitative evaluation shows that the total Coriolis load accounts for less than 4.5% of the overall system dynamics. Therefore, the nominal matrix at 3 m is uniformly adopted for across all three simulation conditions, without scaling with water depth [19].
Substituting the scaled inertia and damping matrices into the continuous-time velocity state-space equation:
Substituting the scaling relations and rearranging yields the following:
Quantitative calculation shows that when g increases from 1.0 to 3.0, the element values of change by less than 4.2%, indicating that the system’s natural frequency and damping ratio only exhibit minor drift within the studied depth range.
In contrast, the control input matrix scales inversely with the total inertia:
For typical open-frame ROVs where added mass dominates the total inertia , , which approximates an inverse proportional scaling relation. In other words, the system input gain decreases significantly as water depth increases. This inverse scaling of the input gain is the dominant source of absolute-scale model mismatch for fixed-gain controllers, and constitutes the root cause of tracking performance degradation under varying water depths.
2.2. Controller Design
To address the model mismatch problem and realize high-precision navigation trajectory optimization under varying water-depth conditions, three types of controllers are sequentially designed in this section for comparative purposes: a PID controller serving as the industrial application baseline, a fixed-parameter MPC controller as the advanced control benchmark, and the proposed adaptive LQR controller based on RLS online identification. All three controllers are designed based on the same ROV dynamic model, with the control input defined as the six-degree-of-freedom generalized thrust and the output as the pose and velocity states, thereby ensuring consistent comparison conditions. The input is the six-thruster thrust vector , and the output comprises the pose states ,.
2.2.1. PID Controller (Baseline)
As the engineering baseline, the PID controller features a simple structure and does not require an accurate system model. Its control law is given as follows:
where is the pose tracking error, and are diagonal gain matrices.
In this study, the PID controller adopts a decoupled diagonal structure, with the gains for each channel independently tuned. Based on simulation tuning at the 3 m water-depth condition, the gain parameters are determined as follows:
For the pitch, roll, and yaw channels, the integral and derivative terms are omitted to avoid noise amplification from the angular velocity signals.
The structural limitations of the PID controller are as follows:
- (1)
- Fixed gains cannot adapt to variations in water depth. The gains tuned at 3 m inevitably suffer from performance degradation under the 5 m and 10 m conditions due to model mismatch;
- (2)
- Risk of integrator windup. During prolonged operations, the accumulated integral term tends to cause overshoot;
- (3)
- Lack of constraint handling. The thrust saturation limits cannot be explicitly addressed.
Consequently, the PID controller yields limited performance under variable operating conditions (i.e., multiple water depths), necessitating the introduction of more advanced control strategies.
2.2.2. Fixed-Parameter MPC Controller (Benchmark)
The discrete-time state-space model at the 3 m water-depth condition is adopted as the prediction model:
where is the augmented state vector, and is the control input.
Over the prediction horizon, the state predictions are given by the following:
At each sampling instant, the MPC solves the following finite-horizon optimal control problem:
where is the prediction horizon, is the control horizon, is the output weighting matrix, is the control increment weighting matrix, and denotes the desired trajectory.
The key parameter configuration of the fixed-parameter MPC is listed in Table 3.
Table 3.
Key parameters of the fixed-parameter MPC controller.
The fixed-parameter MPC solves the optimal control increment at each step using the quadratic programming (QP) algorithm. In the simulations, this is implemented via the MATLAB (R2022b) Model Predictive Control Toolbox, which ensures both optimality and real-time performance of the solution.
The fixed-parameter MPC adopts the fixed parameters at the 3 m water depth as the prediction model. When the actual operational water depth changes to 5 m or 10 m, the prediction model mismatches the actual system, leading to a significant degradation in controller performance.
2.2.3. RLS-Based Adaptive Trajectory Tracking Controller
The proposed controller consists of the following three components:
- (1)
- RLS online identifier: Estimates the equivalent system matrices and of the discrete-time state-space model in real time;
- (2)
- LQR gain scheduler: Recomputes the LQR gain every 50 sampling steps based on the identified results;
- (3)
- Composite control law: Comprises position feedback, velocity feedback, and velocity feedforward.
The ROV dynamic equation is reformulated into the following least-squares identification form:
is the system output, i.e., the velocity state at time step ;
is the regressor vector, composed of the velocity and control input at time step ;
is the parameter matrix to be identified.
The recursive update equations of RLS are given as follows:
where is the forgetting factor, which is used to suppress the influence of old data and enhance the tracking capability for time-varying parameters, and is the covariance matrix. Equations (31)–(33) collectively constitute the complete recursive procedure of the RLS algorithm with a forgetting factor. At the initialization stage, the initial covariance matrix is set to , and the initial parameter matrix is assigned using the nominal model parameters at the 3 m water depth, so as to ensure stable convergence during the initial phase of the algorithm [20,21]. To balance the computational burden and identification accuracy, the RLS update frequency is set to once every 2 sampling steps (i.e., ).
The RLS identifier directly estimates the discrete-time state matrices and in Equation (14). For adaptive LQR design, the identified matrices are used directly without inverse derivation of intermediate hydrodynamic parameters (M, D, C):
This formulation eliminates intermediate transformation errors and reduces online computational steps.
To be consistent with the discrete-time state-space model, the discrete-time algebraic Riccati equation (DARE) is solved:
The optimal state feedback gain is calculated as follows:
In this study, the LQR weighting matrices are set as follows: the state weighting matrix is , corresponding to the tracking weights for position and attitude, and the control input weighting matrix is . The magnitudes of these weights are kept consistent with those of the fixed-parameter MPC to ensure a fair comparison between the different control algorithms [22].
To avoid unnecessary computational burden, the gain scheduling frequency is set to once every 50 sampling steps (i.e., ).
The final control law is a composite of three channels:
: Adaptive position feedback gain updated once every 50 sampling steps;
: Fixed velocity feedback gain;
: Velocity feedforward gain, designed to compensate for the velocity term of the desired trajectory.
The velocity feedback gain is set to , which is consistent with the derivative gains of the PID controller, aiming to increase system damping and suppress oscillations. The velocity feedforward gain is chosen as , which compensates for the velocity term of the reference trajectory and reduces the steady-state tracking error. No feedforward or velocity feedback is configured for the attitude channels [23,24].
Based on the asymptotically unbiased property of the RLS algorithm, under the persistent excitation (PE) condition, the sinusoidal reference trajectory adopted in this study is sufficient to satisfy such an excitation condition, and the parameter estimate converges to with probability 1. When the actual hydrodynamic parameters drift slowly (e.g., at 5 m or 10 m water depths), the RLS algorithm is capable of tracking this drift online, enabling the LQR gain to continuously approach the optimal value, thereby achieving adaptive control.
In this study, a sinusoidal reference trajectory is selected as the excitation signal. Its spectral distribution is sufficient to satisfy the persistent excitation requirement, thereby providing a prerequisite for parameter convergence. Considering that hydrodynamic parameters such as added mass and damping vary slowly during ROV operations at multiple water depths, the forgetting factor is set to . By attenuating the weighting of historical data, the algorithm’s real-time tracking capability for parameter drift is enhanced.
The identified equivalent system matrices and are periodically fed into the LQR module to solve for the optimal feedback gain, thereby realizing adaptive scheduling of the control gains. As long as the identified parameters converge and the discrete-time LQR system itself is stable, the overall closed-loop control system maintains asymptotic stability.
Throughout the entire simulation period, neither divergence nor oscillatory instability is observed in either the identification process or the control loop. This evidence, together with the theoretical analysis, validates the convergence and robust stability of the proposed adaptive architecture and provides a stable numerical basis for online navigation optimization.
2.3. Simulation Experiments
2.3.1. Simulation Platform and Parameter Configuration
To quantitatively evaluate the navigation trajectory optimization performance of the PID, fixed-parameter MPC, and the proposed RLS-based adaptive scheme under different water depths and mismatch degrees, the simulation environment, operating conditions, and evaluation metrics are uniformly configured in this section, and a series of comparative simulation experiments are conducted. The root mean square error (RMSE) is adopted as the performance metric for trajectory tracking evaluation. To eliminate the influence of the initial transient processes, the steady-state data from 10 s to 200 s are uniformly selected for RMSE calculation, ensuring that the evaluation criteria remain entirely consistent across different algorithms and operating conditions.
2.3.2. Simulation Environment
The simulations are implemented in the MATLAB R2022b/Simulink R2022b environment, using a fixed-step solver with a step size of and a total simulation duration of 200 s. All three types of controllers are deployed within the same Simulink model to ensure a fair comparison.
2.3.3. Controller Parameters
The key parameters of the three types of controllers are summarized in Table 4.
Table 4.
Key parameters of the three controllers.
2.3.4. Multi-Water-Depth Condition Set Up
To evaluate the adaptability of the controllers under varying water depths, three sets of comparative conditions are established in this study. Considering the influence of increasing water depth on the ROV hydrodynamics, the water-depth gain coefficients (, ) are introduced to model the actual hydrodynamic parameters as follows:
where denotes the target water depth , and and are the nominal parameters at the 3 m water depth. The Coriolis matrix remains unchanged across all three conditions. The water-depth gain coefficients for each condition are listed in Table 5.
Table 5.
Parameter settings for multi-water-depth conditions.
Physical basis of the parameter settings:
- (1)
- Equal-proportional scaling property : As water depth increases, the slight increase in fluid density causes the added mass and the linear damping to increase proportionally, with their ratio remaining approximately unchanged. Consequently, the dimensionless dynamic characteristics of the system, such as the damping ratio and time constants, remain stable;
- (2)
- Absolute-scale mismatch: Although the dynamic characteristics remain invariant, the absolute magnitudes of the damping forces and inertial forces increase, resulting in an “absolute-scale” mismatch between the prediction model used by the fixed-parameter MPC and the actual system;
- (3)
- Invariance of the Coriolis matrix: The Coriolis force is dominated by the term , and the coupling coefficients are mainly determined by the ROV geometry layout, with water-depth variation exerting a relatively minor influence. Therefore, the Coriolis matrix is treated as constant in this study. In summary, the Coriolis matrix is primarily governed by the geometric structure and mass distribution of the ROV hull, and is minimally affected by water depth or fluid environmental changes. Hence, its nominal value is uniformly adopted across all three conditions, while only the added mass and linear damping are scaled. This modeling approach closely reflects the actual underwater dynamic characteristics.
2.3.5. Desired Reference Signal
To evaluate the reference signal tracking performance of the three types of controllers, an orthogonal sinusoidal reference signal is designed in the horizontal plane as the desired trajectory. Both the X-axis and Y-axis reference signals are sinusoidal functions, given as follows:
where the amplitude is , the angular frequency is , denotes the target water depth , and is the simulation time. The adoption of orthogonal sinusoidal signals as the reference trajectory not only enables a comprehensive evaluation of the two-dimensional tracking capability in the horizontal plane, but also provides persistent excitation for the RLS online identification, thereby ensuring proper parameter convergence.
The desired velocity signals are given as follows:
The initial states of the ROV are set as follows:
That is, the ROV is initially located at the origin (0, 0) in the X–Y plane with zero initial velocities, and waits for the controller to initiate the tracking task.
3. Results
3.1. 3 m Water Depth (Nominal Condition)
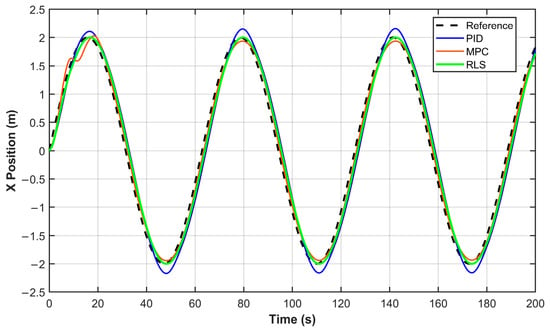
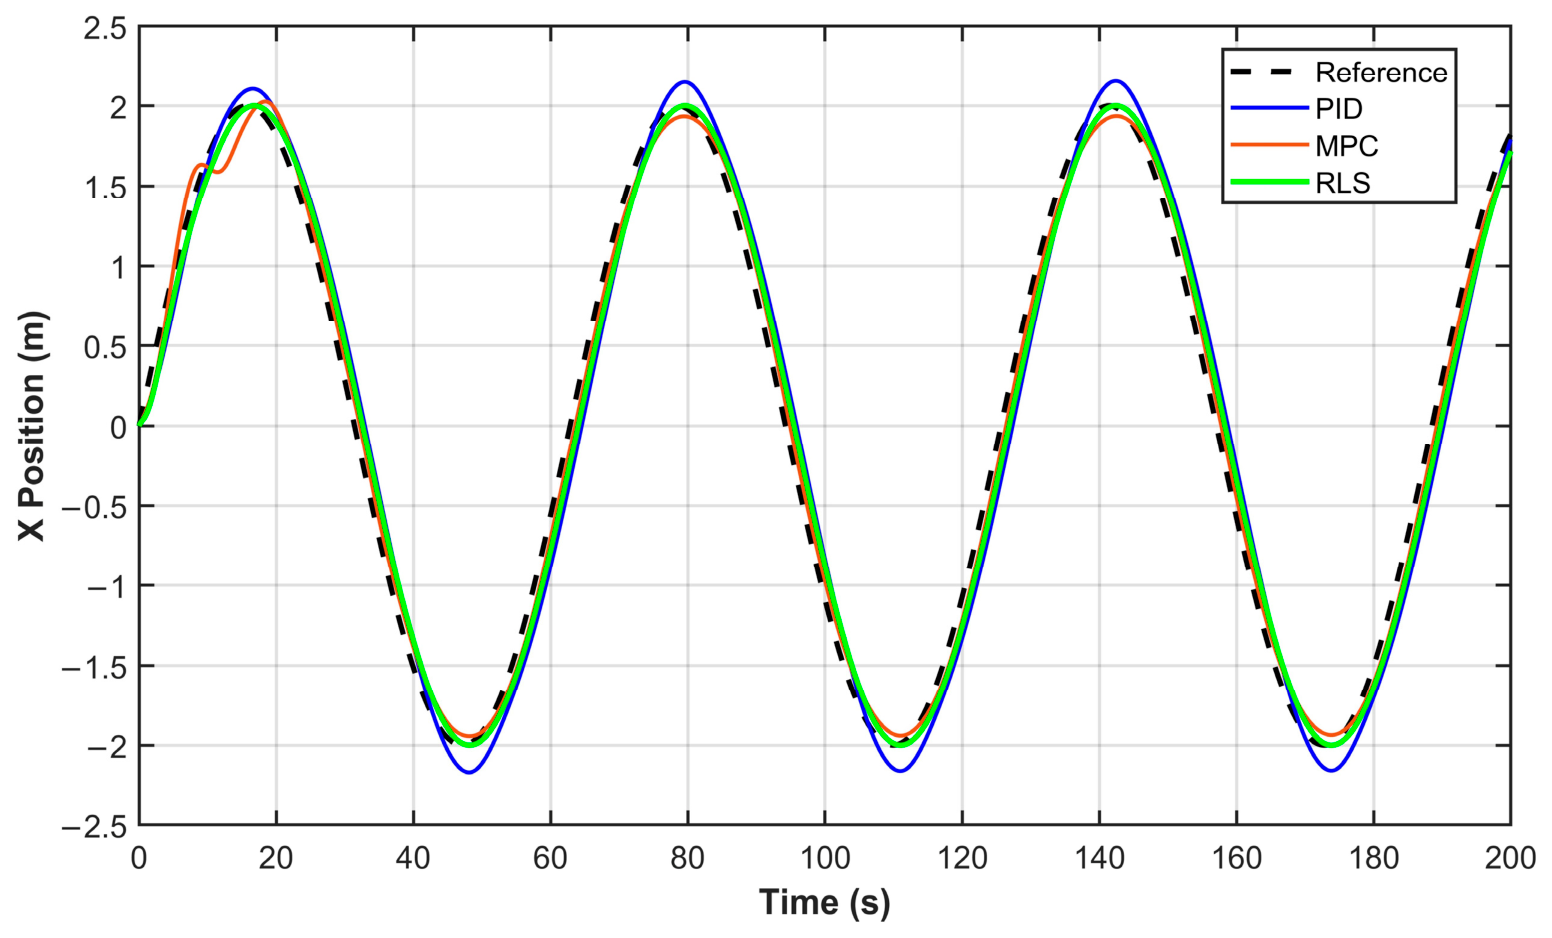
Figure 2.
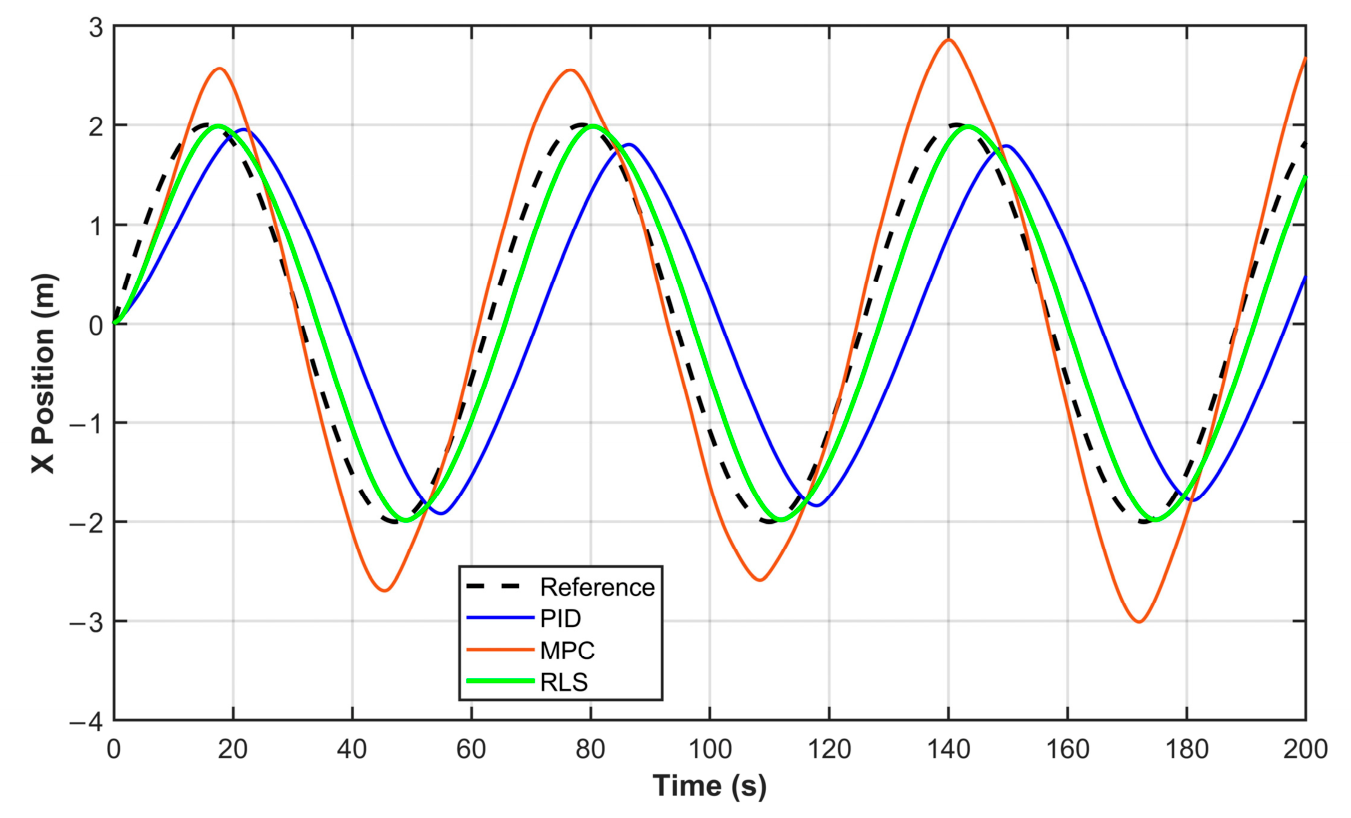
X-axis tracking results of the reference signal at 3 m water depth (nominal condition).
Figure 3.
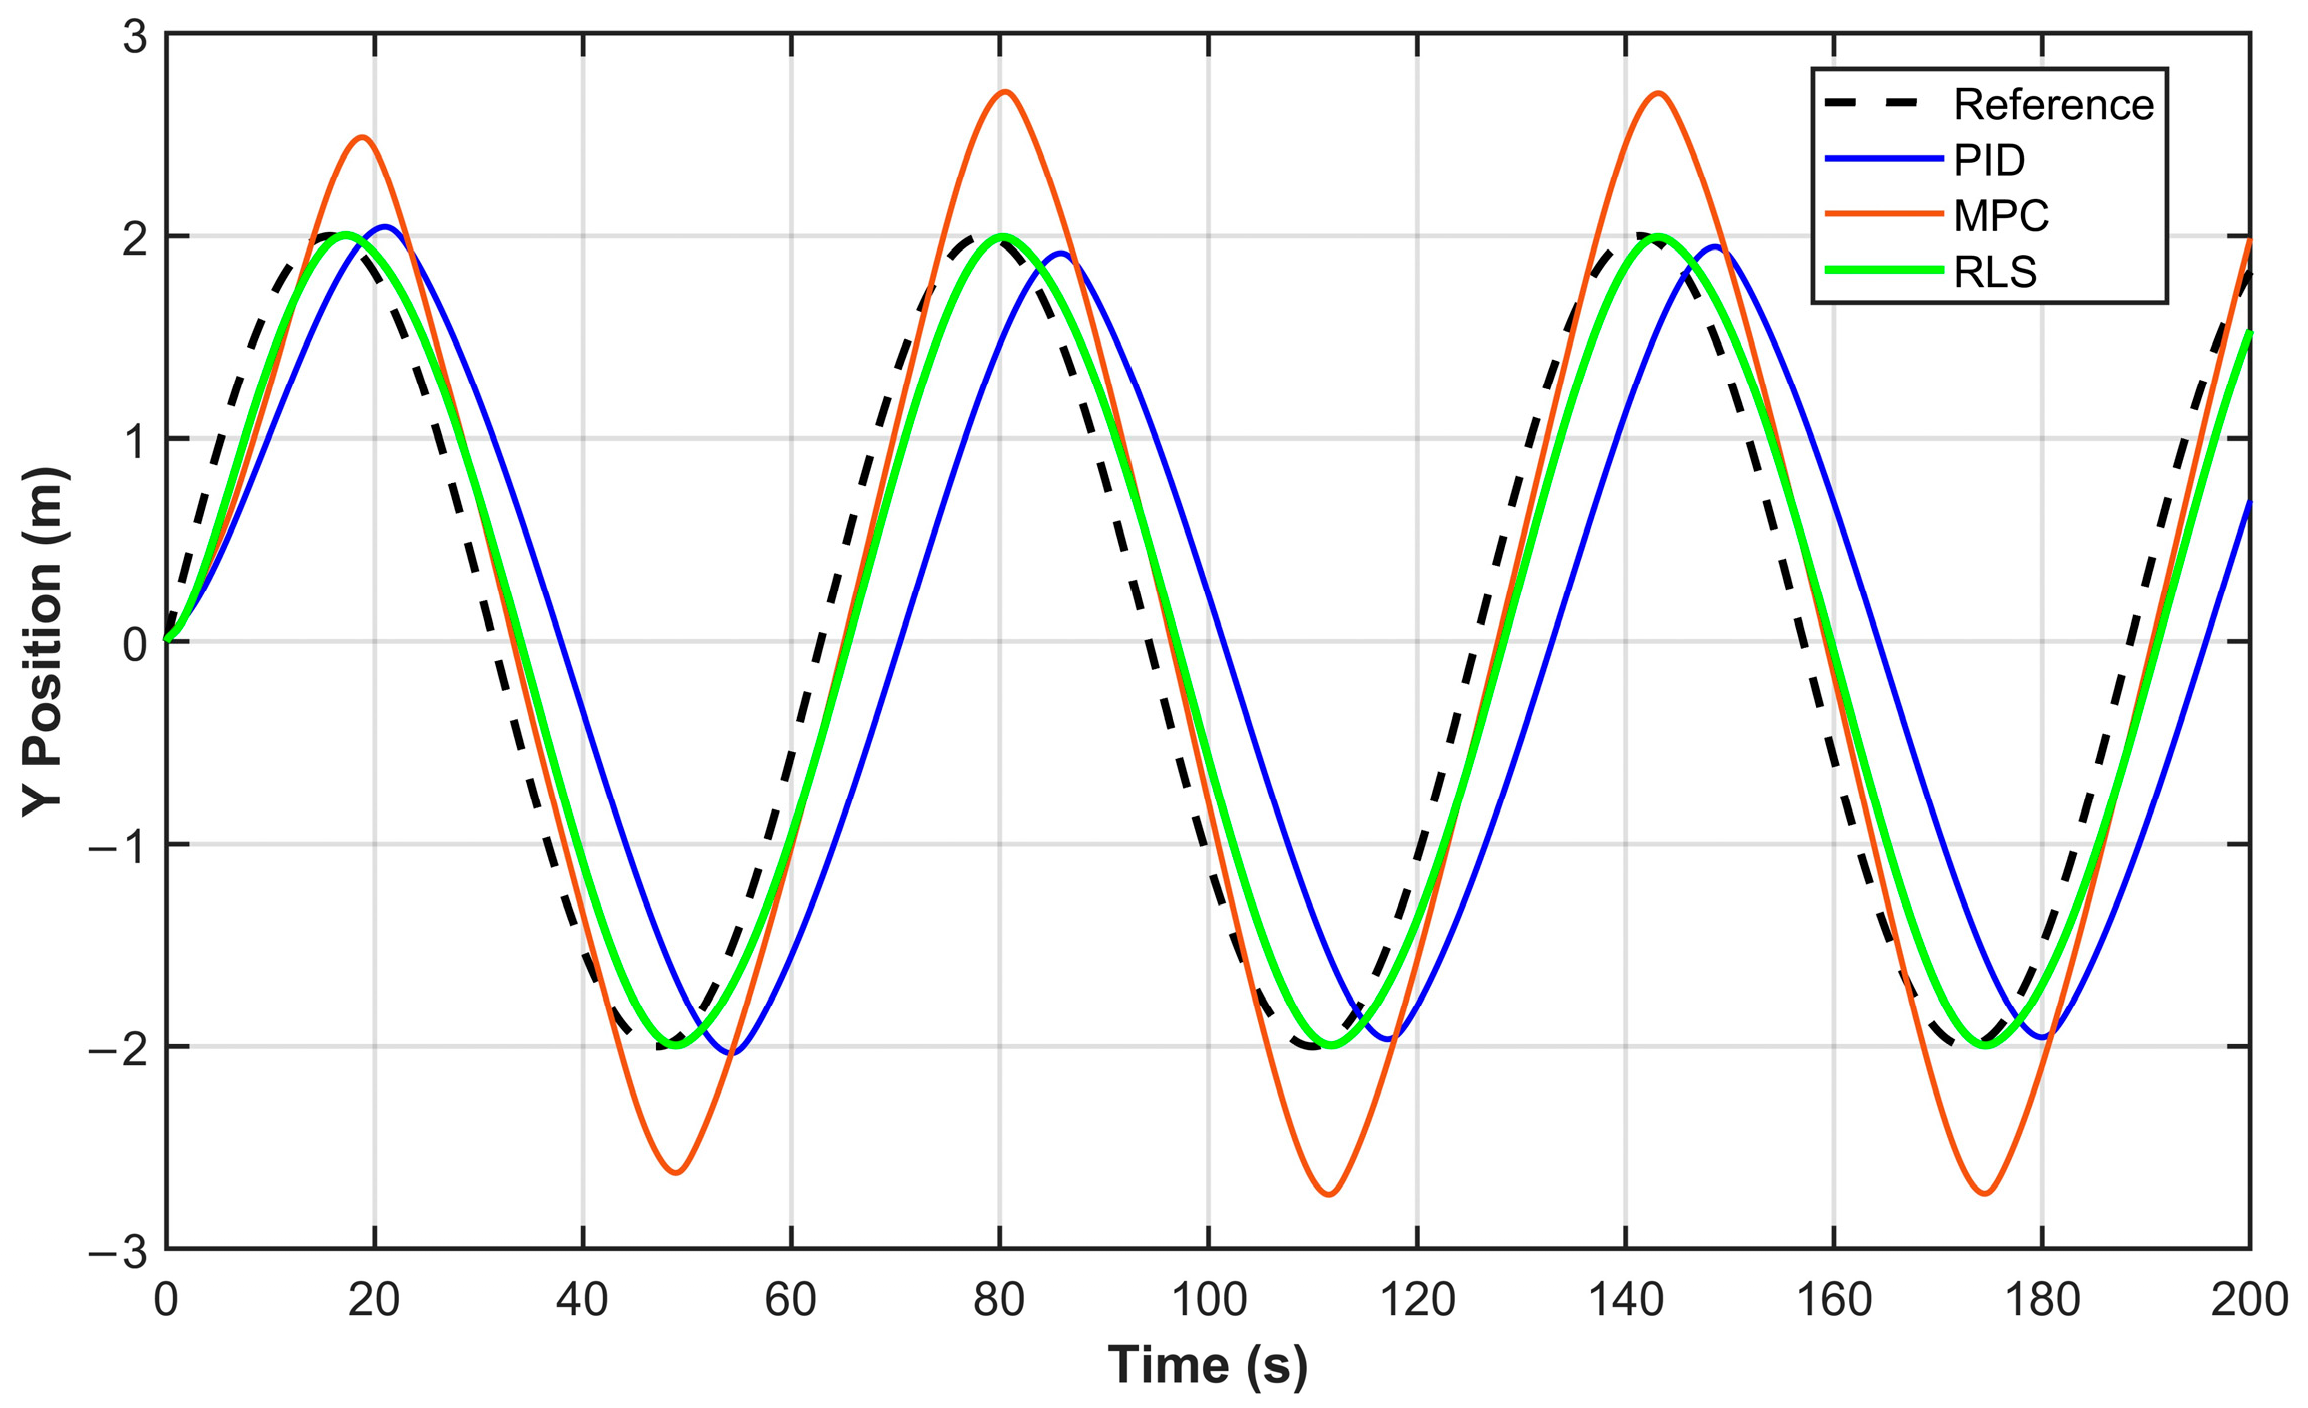
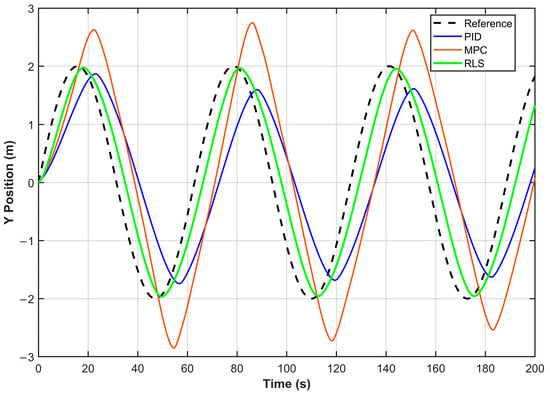
Y-axis tracking results of the reference signal at 3 m water depth (nominal condition).
The RMSE comparison results are shown in Table 6:
Table 6.
RMSE comparison at 3 m water depth (nominal condition).
The improvement rates are presented in Table 7:
Table 7.
Improvement rates at 3 m water depth.
3.2. Five-Meter Water Depth (Moderate Mismatch Condition)
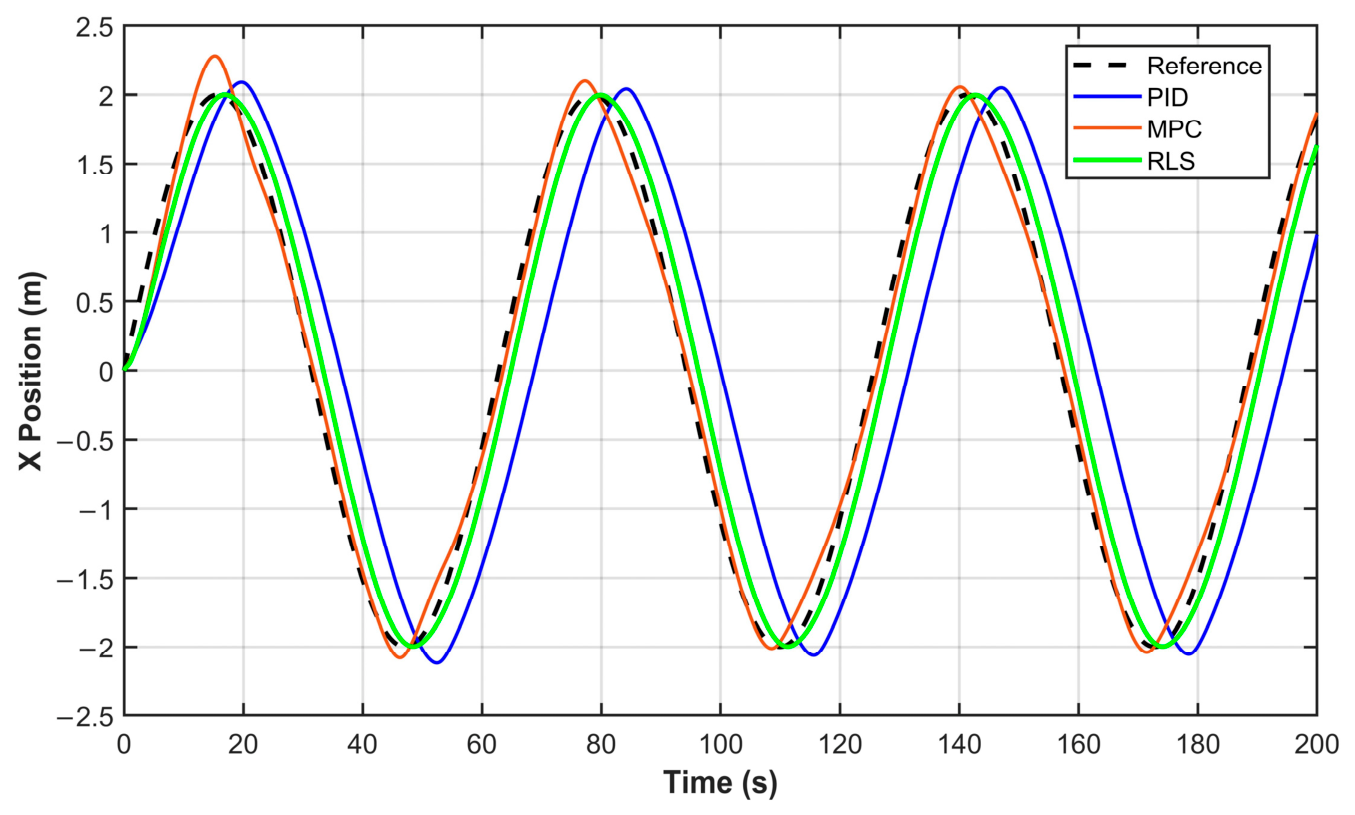
Figure 4.
X-axis tracking results of the reference signal at 5 m water depth (moderate mismatch condition).
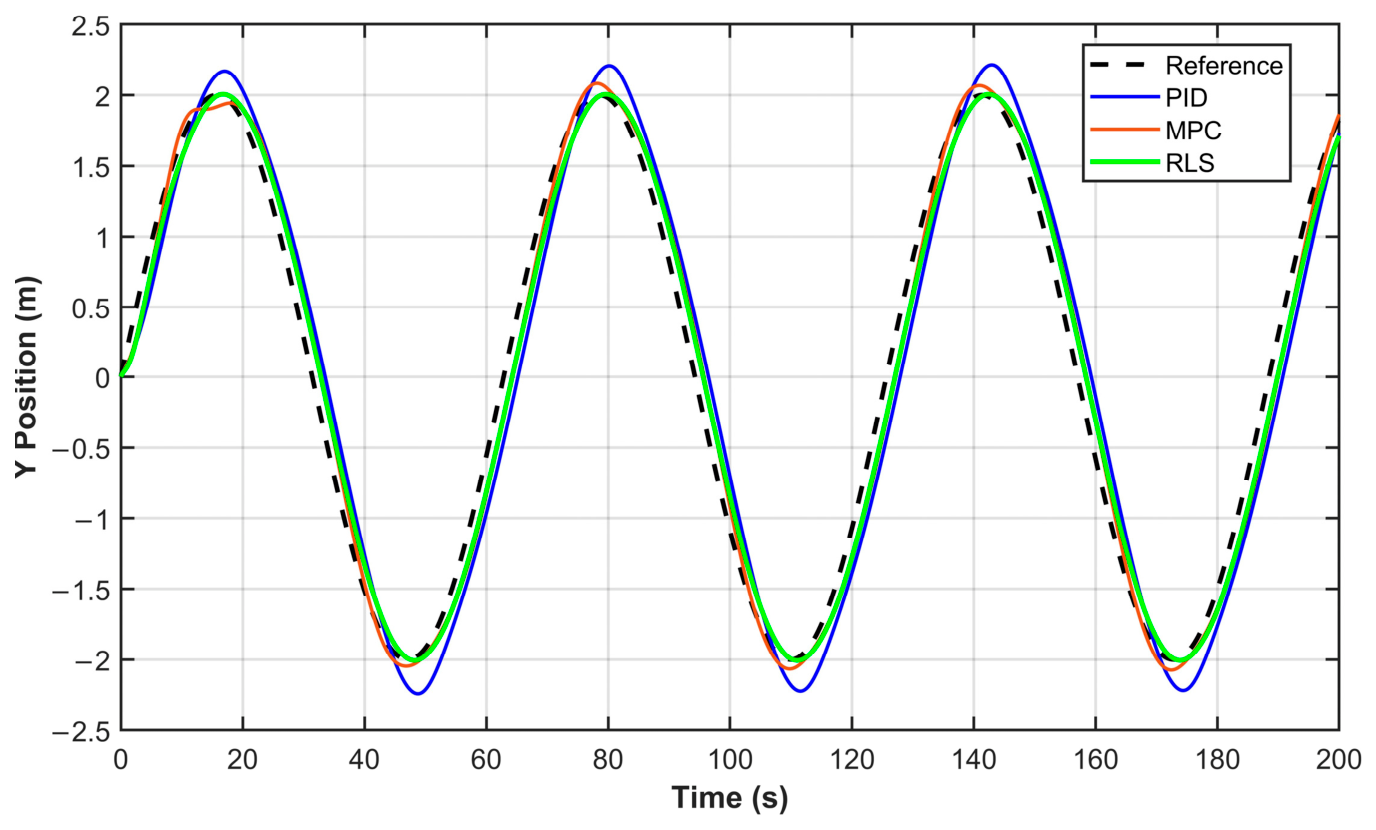
Figure 5.
Y-axis tracking results of the reference signal at 5 m water depth (moderate mismatch condition).
The RMSE comparison results are shown in Table 8:
Table 8.
RMSE comparison at 5 m water depth (moderate mismatch condition).
The improvement rates are presented in Table 9:
Table 9.
Improvement rates at 5 m water depth.
3.3. Ten-Meter Water Depth (Severe Mismatch Condition)
Figure 6.
X-axis tracking results of the reference signal at 10 m water depth (severe mismatch condition).
Figure 7.
Y-axis tracking results of the reference signal at 10 m water depth (severe mismatch condition).
The RMSE comparison results are shown in Table 10:
Table 10.
RMSE comparison at 10 m water depth (severe mismatch condition).
The improvement rates are presented in Table 11:
Table 11.
Improvement rates at 10 m water depth.
3.4. Cross-Case Robustness Analysis
To quantitatively evaluate how the performance of fixed-parameter MPC degrades with depth-induced model mismatch, two performance degradation criteria are defined: (1) the horizontal 2D trajectory RMSE exceeds 200% of the tracking error obtained under nominal conditions (3 m depth, ); (2) the thruster saturation ratio is greater than 30%. The tracking performance is regarded as severely degraded only when both criteria are satisfied simultaneously.
Based on the fixed-point simulation results across three water-depth cases in Section 3.1, Section 3.2 and Section 3.3 (, 2.2, 3.0) and trend interpolation, the critical model mismatch threshold of fixed-parameter MPC is determined as . When g is below this threshold, the inherent constraint handling capability of MPC can compensate for moderate model mismatch. Once g exceeds this threshold, continuous actuator saturation will trigger sharp deterioration of tracking accuracy. A full high-density systematic parameter sweep over the range will be supplemented in future tank-test related studies.
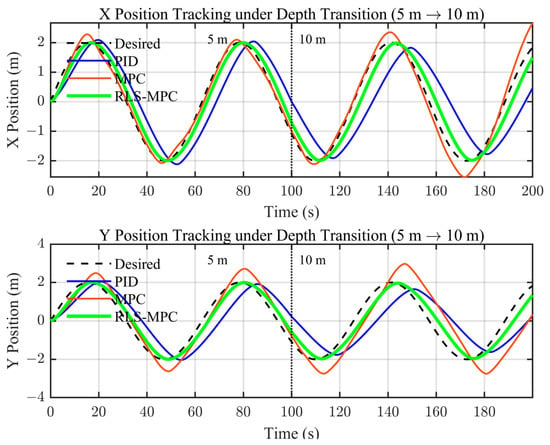
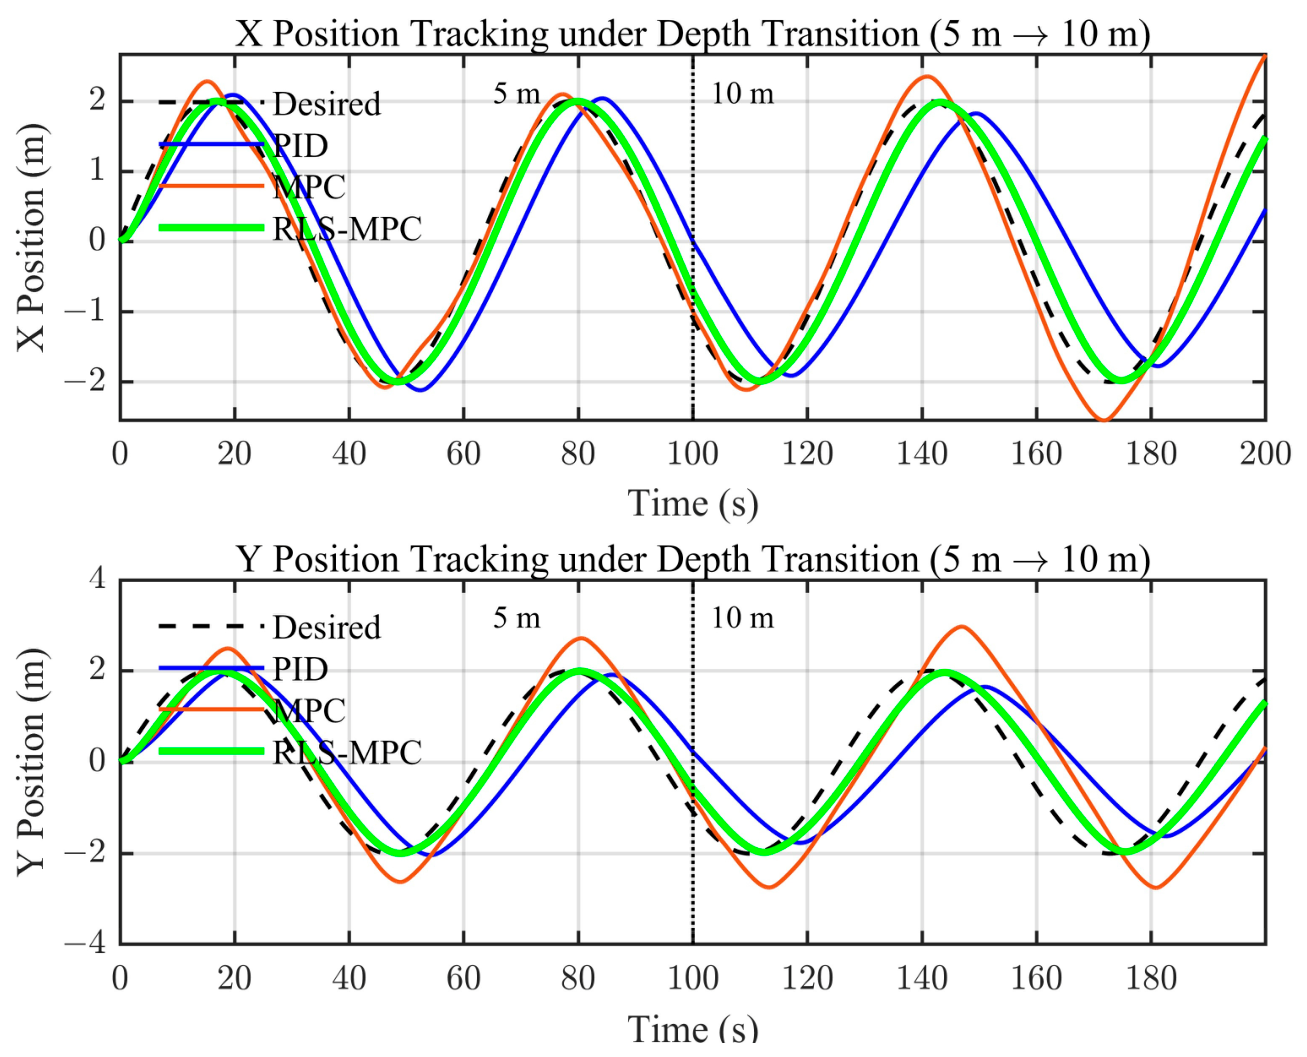
To examine the adaptive performance under time-varying operating conditions, a simulation with depth transition from 5 m to 10 m is implemented. The reference trajectory is kept consistent with previous tests. As illustrated in Figure 8, RLS-LQR online updates and and periodically refreshes the LQR gains during depth variation, maintaining satisfactory tracking performance. After the depth jumps to 10 m at , both fixed-parameter PID and fixed-parameter MPC show gradually increasing tracking deviations from the desired trajectory. This case confirms that the controller’s robustness extends beyond static fixed-depth operating points.
Figure 8.
X and Y position tracking performance of fixed PID, fixed-parameter MPC, and the proposed RLS-LQR under depth transition from 5 m to 10 m.
4. Discussion
The comparative results across three depth conditions demonstrate that fixed-gain controllers (PID and fixed-parameter MPC) exhibit continuously growing tracking errors as water depth increases and model mismatch intensifies. The channel compensation capability of MPC provides limited robustness only under mild-to-moderate mismatch; once the scaling factor exceeds approximately 2.5, thrust saturation exhausts the optimization degrees of freedom, leading to complete performance collapse. This quantitative threshold provides a clear design reference for determining the applicable scope of fixed-parameter ROV controllers in variable-depth operations.
The proposed RLS-LQR adaptive architecture achieves stable tracking performance across all three scenarios. Under the nominal 3 m condition, its steady-state RMSE is 17.8% higher than that of fixed-parameter MPC, but remains within the same accuracy level. Its advantage becomes prominent under mismatch conditions: by periodically updating the state-space model and recalculating the optimal feedback gains, the controller compensates for the absolute-scale input gain mismatch caused by inertia-damping coordinated scaling. From a theoretical perspective, this work verifies that the root cause of depth-induced performance degradation lies in the inverse scaling of the input matrix rather than drift of the system state matrix, which explains why fixed-gain controllers universally suffer from reduced response bandwidth and increased steady-state error under deep-water conditions.
From an engineering feasibility perspective, the RLS identification algorithm has extremely low computational overhead. The computational performance is tested on an embedded platform with an ARM Cortex-M7 microcontroller (216 MHz, 512 KB RAM) using a pure C implementation. The single-step RLS update takes approximately 6.2 ms, and one LQR gain calculation takes approximately 28 ms. Since gain scheduling runs every 5 s, the average processor load is less than 1%, fully satisfying real-time requirements for ROV embedded control. Throughout the 200 s simulation, no oscillation or divergence occurs, indicating that the algorithm has satisfactory numerical stability and is suitable for embedded deployment on actual ROV control systems.
Nevertheless, this study has certain limitations. All validations are conducted in simulation environments, and real-world factors such as sensor noise, thruster nonlinearities, and communication delays are not fully considered. In addition, the current parameter variation model adopts a simplified coordinated scaling assumption, and actual density gradients and nonlinear flow effects may require more refined hydrodynamic modeling. Future work will verify the method through tank tests and field trials on real ROV platforms.
5. Conclusions
This paper addresses the trajectory tracking performance degradation of fixed-parameter ROV controllers caused by hydrodynamic parameter drift under varying water depths. An adaptive trajectory tracking control method based on RLS online identification and periodic LQR gain scheduling is proposed and quantitatively validated through comparative simulations under three depth conditions. The main conclusions are as follows:
Water-depth variations proportionally scale both added mass and linear damping by the same factor. Theoretical derivation proves that the system state matrix is barely affected by scaling, while the control input matrix varies inversely with the scaling factor, resulting in absolute-scale model mismatch. This is the intrinsic mechanism of performance degradation for fixed-gain controllers.
Under the nominal 3 m condition, the proposed method achieves steady-state performance comparable to fixed-parameter MPC, with a 17.8% larger 2D RMSE but remaining within the same accuracy level. Under moderate mismatch (5 m, g = 2.2), the 2D resultant RMSE is reduced by 8.4% compared with fixed-parameter MPC. Under severe mismatch (10 m, g = 3.0), the RMSE reduction reaches 57.4%, demonstrating significant advantages in robustness. The proposed method trades off a small amount of nominal performance for strong adaptability to depth-varying conditions, which is more suitable for ROV operations with large depth spans.
The compensation capacity of fixed-parameter MPC has a critical threshold at a scaling factor of approximately 2.5. Beyond this boundary, the channel compensation mechanism completely collapses. This quantitative boundary provides a reference for engineering controller selection.
The proposed algorithm has low computational complexity and stable numerical performance, making it suitable for embedded real-time control applications on engineering ROV systems.
Future work will extend the method to full-DOF coupled identification, integrate MPC constraint-handling capability to construct an adaptive MPC framework, and conduct experimental validation on actual ROV platforms.
Author Contributions
X.S.: Writing—original draft, Software, Formal analysis, Data curation. G.C.: Methodology, Validation, Resources. H.Y.: Visualization, Investigation, Writing—review and editing. P.S.: Conceptualization, Supervision, Project administration, Writing—review and editing. All authors have read and agreed to the published version of the manuscript.
Funding
This work was supported by the Independent Research Project of Naval University of Engineering (Grant No. 2026502010).
Data Availability Statement
The simulation data and code supporting the findings of this study are available from the corresponding author upon reasonable request.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Yin, C.W.; Riaz, S. ROV high precision predefined time convergence sliding mode control: Based on a novel stability criteria. Int. J. Control Autom. Syst. 2025, 23, 3014–3024. [Google Scholar] [CrossRef] [Scilit]
- Zhang, D.; Zhao, B.; Zhang, Y. Numerical simulation of hydrodynamics of ocean-observation-used remotely operated vehicle. Front. Mar. Sci. 2024, 11, 1357144. [Google Scholar] [CrossRef] [Scilit]
- Yang, G.; Liu, W.; Li, L.; Xu, J.; Guo, L.; Zhang, K. Optimized trajectory tracking for ROVs using DNN + ENMPC strategy. J. Mar. Sci. Eng. 2024, 12, 1827. [Google Scholar] [CrossRef] [Scilit]
- Zhang, D.; Wang, X.; Zhao, M.; Hong, L.; Li, X. Numerical investigation on hydrodynamic characteristics and drag influence of an open-frame remotely operated underwater vehicle. J. Mar. Sci. Eng. 2023, 11, 2143. [Google Scholar] [CrossRef] [Scilit]
- Delgado-Pamanes, M.F.; Silva-Morales, B.; Reyes-Osorio, L.A.; Garcia-Salazar, O.; Vázquez-Tzompantzi, M.; Munoz-Vazquez, A.J. Mathematical modeling and simulation of a hybrid additive–subtractive ROV with experimental validation for reef exploration. Mathematics 2026, 14, 1723. [Google Scholar] [CrossRef] [Scilit]
- Zhao, C.; Thies, P.R.; Johanning, L.; Tobin, S. Modelling and assessment of ROV capacity within an autonomous offshore intervention system. In Developments in Renewable Energies Offshore: Proceedings of the 4th International Conference on Renewable Energies Offshore (RENEW 2020); CRC Press: Lisbon, Portugal, 2021. [Google Scholar] [CrossRef] [Scilit]
- Fan, S.; Wang, H.; Zuo, C.; Han, J. Fuzzy adaptive PID-based tracking control for autonomous underwater vehicles. Actuators 2025, 14, 470. [Google Scholar] [CrossRef] [Scilit]
- Tun, T.T.; Huang, L.; Preece, M.A. Development and high-fidelity simulation of trajectory tracking control schemes of a UUV for fish net-pen visual inspection in offshore aquaculture. IEEE Access 2023, 11, 135764–135787. [Google Scholar] [CrossRef] [Scilit]
- Wang, J.; Yan, S.; Bao, H.; Chen, C.; Yu, D.; Li, J.; Chen, X.; Dou, R.; Tang, Y.; Li, S. Reinforcement-learning-based adaptive PID depth control for underwater vehicles against buoyancy variations. J. Mar. Sci. Eng. 2026, 14, 323. [Google Scholar] [CrossRef] [Scilit]
- Li, D.; Zheng, Z.; Ding, Z.; Yang, J.; Yang, L. Research on trajectory tracking control method for seabed wheeled robots based on GPSO-MPC. Sensors 2025, 25, 4882. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Tran, C.; Øveraas, H.; Johansen, T.A. ROV recovery with wave-motion compensation using model predictive control. Ocean. Eng. 2024, 293, 116764. [Google Scholar] [CrossRef] [Scilit]
- Walker, K.L.; Giorgio-Serchi, F. Nonlinear model predictive dynamic positioning of a remotely operated vehicle with wave disturbance preview. Int. J. Robot. Res. 2024, 44, 932–951. [Google Scholar] [CrossRef] [Scilit]
- Xia, T.; Yang, Q.; Huang, B.; Ouyang, Y.; Zheng, Y.; Mao, P. Enhanced trajectory tracking control algorithm for ROVs considering actuator saturation, external disturbances, and model parameter uncertainties. Ocean. Eng. 2024, 304, 118973. [Google Scholar] [CrossRef] [Scilit]
- Kang, H.; Li, J.; Kim, M.; Jin, H. Estimation of hydrodynamic coefficients for the underwater robot P-SUROII via constrained recursive least squares method. J. Mar. Sci. Eng. 2025, 13, 1610. [Google Scholar] [CrossRef] [Scilit]
- Liu, J.; Chang, L.; Xu, L.; He, F.; He, Y. Research on the on-line identification of ship maneuvering motion model parameters and adaptive control. J. Mar. Sci. Eng. 2025, 13, 753. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Sun, B. Learning-aided adaptive robust control for spiral trajectory tracking of an underactuated AUV in net-cage environments. Appl. Sci. 2025, 15, 10477. [Google Scholar] [CrossRef] [Scilit]
- Eng, Y.H.; Chin, C.S.; Lau, M. Added mass computation for control of an open-frame remotely-operated vehicle: Application using WAMIT and MATLAB. J. Mar. Sci. Technol. 2014, 22, 405–416. [Google Scholar] [CrossRef]
- Aryawan, W.D.; Utama, I.K.A.P.; Hermawan, Y.A.; Sutiyo. CFD analysis into the resistance characteristics of remotely operated vehicles when submerged under water and sailing on the surface. CFD Lett. 2023, 15, 166–178. [Google Scholar] [CrossRef] [Scilit]
- Zhang, W.; Xu, T.J. Numerical simulation analysis of hydrodynamic characteristics of open-frame ROVs. Chin. J. Ship Res. 2025, 20, 111–123. [Google Scholar] [CrossRef]
- Chu, Z.; Zhu, D.; Yang, S.X. Observer-Based Adaptive Neural Network Trajectory Tracking Control for Remotely Operated Vehicle. IEEE Trans. Neural Netw. Learn. Syst. 2017, 28, 1633–1645. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zhu, M.; Hahn, A.; Wen, Y.Q.; Bolles, A. Parameter Identification of Ship Maneuvering Models Using Recursive Least Square Method Based on Support Vector Machines. TransNav Int. J. Mar. Navig. Saf. Sea Transp. 2017, 11, 23–29. [Google Scholar] [CrossRef] [Scilit]
- Shen, C.; Shi, Y.; Buckham, B. Trajectory Tracking Control of an Autonomous Underwater Vehicle Using Lyapunov Based Model Predictive Control. IEEE Trans. Ind. Electron. 2018, 65, 5796–5805. [Google Scholar] [CrossRef] [Scilit]
- Yuh, J. Modeling and control of underwater robotic vehicles. IEEE Trans. Syst. Man. Cybern. 1990, 20, 1475–1483. [Google Scholar] [CrossRef] [Scilit]
- Zhong, Y.; Yu, C.; Xiang, X.; Lian, L. Dynamics identification-driven diving control for unmanned underwater vehicles. J. Field Robot. 2025, 42, 79–96. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.