


Abstract
Subsynchronous oscillation (SSO) is the resonance between a new energy generator set and a weak power grid, and the resonance frequency is usually the sub-/super-synchronous frequency. The eigensystem realization algorithm (ERA) is a classic algorithm for extracting modal parameters based on matrix decomposition. By leveraging the ERA’s simplicity and low computational cost, an enhanced methodology for identifying the key parameters of SSO is introduced. The enhanced algorithm realizes SSO angular frequency extraction by constructing an angular frequency fitting equation, enabling efficient identification of SSO parameters using only a 200 ms synchrophasor sequence. In the process of identification, the fitting-based ERA effectively addresses the limitation of the existing ERA. The accuracy of SSO parameter identification is improved, thereby realizing that SSO parameter identification can be carried out using a 200 ms data window. The fitting-based ERA is verified using synthetic and actual data from synchrophasor measurement terminals. The research results show that the proposed algorithm can accurately extract fundamental and subsynchronous or supersynchronous oscillation parameters, effectively realizing dynamic real-time monitoring of subsynchronous oscillations.
1. Introduction
In the modern energy system involving renewable energy, with the large-scale grid integration of new energy power generation and the widespread application of various high-capacity power electronic devices, the problem of subsynchronous oscillations (SSOs) has become increasingly serious [1,2,3,4,5,6]. SSOs occur when the voltage and current frequency in a power supply system are less than the synchronous frequency. In certain situations, the presence of higher-frequency supersynchronous components may also be observed. In light of the multifaceted negative impacts of SSOs on power systems, such as reducing power transmission efficiency, endangering overall system stability, and triggering instability, we must attach great importance to and strengthen comprehensive monitoring and in-depth analysis of their dynamic processes within a system. Swift and effective control measures must be implemented to prevent SSOs from occurring, ensuring the stability and reliability of a power grid [7,8].
There are many methods for identifying SSO parameters. However, the existing algorithm mainly has two shortcomings; the first is the poor accuracy of SSO parameter recognition, and the second one is the long data window. Several methods exist for detecting the dynamic processes associated with subsynchronous oscillations using fault recorders (FRs) [9,10,11]. However, acquiring instantaneous data promptly poses a challenge, as these data are primarily sourced from FRs located at various buses. Moreover, the need for unified timing standards for FRs complicates the process of dynamically and comprehensively observing subsynchronous oscillations.
Currently, the wide area measurement system (WAMS) and phasor measurement units (PMUs) have achieved widespread adoption in modern power grids [12,13,14]. The biggest highlight of using synchrophasor data for SSO analysis lies in its ability to integrate measurement data from different power stations onto a unified time base, facilitating direct and accurate comparisons.
Among the prevalent SSO parameter identification techniques incorporating synchrophasors, algorithms rooted in the discrete Fourier transform (DFT) have garnered significant attention and research. In [15], the specific impacts of the discrete Fourier transform algorithm and the sampling rate of synchrophasors on the magnitude spectrum were analyzed utilizing a WAMS and PMUs. This furnished a correction ratio which enabled precise identification of SSO parameters, thereby enhancing the accuracy of the analysis. However, the requirement of ensuring at least a 10 s data window for accurate extraction of SSO parameters when adopting this method may impose certain limitations on its reliability and real-time response capability in capturing rapidly fluctuating SSOs. Hence, several researchers have introduced an interpolation-DFT method improved by employing a Hann-window [16,17]. This innovative approach both shrinks the necessary data window down to 2 s only and successfully mitigates the impact of spectrum aliasing, enhancing the overall accuracy and efficiency of the analysis.
Among the non-DFT algorithms, two primary modal parameter extraction methods exist which rely on the synchrophasor sequence [18]. These two methods are the eigensystem realization algorithm (ERA) [19] and the matrix pencil method (MPM) [20,21,22]. The spectral resolution poses fewer constraints on non-DFT algorithms, allowing for the utilization of a shorter data window of 2 s. While the method mentioned above effectively guarantees a certain level of accuracy in identifying SSO parameters, a 2 s data window remains relatively lengthy. Due to the introduction of new energy-generating units, the dynamic speed of subsynchronous oscillation is extremely fast, and thus we need to monitor subsynchronous oscillation quickly and synchronously. The existing 2 s data window is no longer sufficient for fast and synchronous monitoring of SSO. Furthermore, the existing method has shortcomings, such as failing to consider the conjugate relationship of angular frequencies, resulting in poor SSO parameter identification accuracy, and only being able to shorten the data window to 2 s.
Classic ERA technology achieves precise and convenient extraction of modal parameters by simplifying the process of matrix decomposition. However, it also has obvious shortcomings. One needs a data window of 1 s to ensure the accuracy of the parameter identification results, and the other fails to take into account the conjugate relationship of angular frequencies. During the course of this research, we conduct our analysis, dependent upon a fixed model. However, in actuality, the actual waveform is changing, and thus the model should also change. The use of an extended data window will further constrain us within the fundamental assumption that the model is fixed and unchanging. Consequently, in practical applications, shortening the data window is particularly important. But, the research uncovered that the ERA’s rate of identification accuracy will be significantly decreased after compressing the data window. Based on this, we have optimized the algorithm to ensure that it can maintain exceptional accuracy even under the condition of a shortened data window, which forms the core starting point of all of our work.
In this paper, the existing ERA is improved by fitting equations from the aspect of solving the angular frequency, and the angular frequency obtained by the improved algorithm meets the constraint of pairwise conjugation. This improves the accuracy of SSO parameter identification and further shows that the 200 ms data window can be used for SSO parameter identification. Moreover, using a 200 ms data window in this paper can capture the dynamics of SSO to the order of milliseconds, which can minimize the limitations caused by the assumption that the model is fixed within the data window. Finally, the fitting-based ERA method is simulated using synthesized and measured PMU data. The simulation results show that the fitting-based ERA can shorten the data window duration to 200 ms and ensure the accuracy of SSO parameter identification.
This paper is organized as follows. Section 2 studies the synchrophasor model and modal parameter extraction in the ERA. Section 3 introduces SSO parameter identification of the fitting-based ERA. In Section 4, the proposed method’s performance is evaluated using the synthesized and measured PMU data.
2. Synchrophasor Sequence Modal Models and Extraction of Modal Parameters
2.1. Synchrophasor Sequence Modal Models with Sub- or Super-Synchronous Components
Firstly, the instantaneous signal model of the current or voltage of the power system is established, and it is assumed that the model remains fixed in the selected data window, which is denoted as and expressed as shown in Equation (1):
where f, x and represent the frequency, amplitude and initial phase, respectively. The subscripts “” stand for the fundamental component, subsynchronous component and supersynchronous component, respectively.
According to the standard IEEE std C37.118 [23], for the DFT, Equation (1) is used to obtain the synchrophasor sequence corresponding to the instantaneous signal . This expression is shown in Equation (2):
where N is the number of data points when calculating the synchrophasors according to the instantaneous value.
Euler’s formula is applied to Equation (2) to divide the synchrophasors corresponding to different components into positive frequency components and negative frequency components. Taking the supersynchronous component as an example, when the current sampling time is , its decomposition process is as follows:
In this formula, the superscript “*” indicates conjugation, is the uploading frequency of the synchronous phasor data, and . The function is introduced to represent the calculation process of synchrophasors, f can be the frequency of each component, and m is . Its expression is
The fundamental, subsynchronous and supersynchronous components all encompass frequency components which are both positive and negative in nature. Therefore, the expression of each component of the synchrophasor is as follows:
In this formula, the superscripts “+” and “−” indicate the positive frequency and negative frequency components of each component, respectively.
In Equation (5), the angular frequency of each component is introduced, and its expression is
The subsynchronous and supersynchronous components constitute a paired set of frequency-coupled oscillation elements exhibiting interdependent dynamic oscillations. The frequency of the fundamental component is close to the rated frequency of the power system, and the relationship between their frequencies is .
Accounting to Equation (6), and can be deduced. To simplify Equation (5), let . and can be combined into an oscillation component to simplify the synchrophasor sequence , and thus we have
Since the ERA can be synonymously reformulated as a technique for extracting modal parameters, we study the modal model of synchrophasors. According to [15], the synchrophasors can be expressed as the sum of four modes, as shown in the following formula:
where is the angular frequencies and is the constant parameters, while k denotes the temporal variation characteristics of the angular frequency.
2.2. Extracting the Parameters of the Modal Model
Extracting the angular frequency parameters of SSOs from massive synchrophasor data is a typical problem when identifying modal parameters. The ERA serves as a prototypical algorithm for the extraction of modal parameters. Constructing the Hankel matrix and system matrix reformulates the process of modal parameter extraction into a matrix decomposition problem. This method can directly determine the angular frequency of the fundamental wave component and oscillation component with a low calculation cost and high solution efficiency.
The ERA skillfully uses the temporal continuity of the synchrophasor sequence to extract information by constructing two Hankel matrices with specific shifts. By leveraging the correspondence between two translated Hankel matrices, the system’s matrix can be acquired. Then, the parameters of the SSOs are further identified based on the system matrix.
In the field of SSO parameter identification, there are many methods, but in contrast, the ERA method stands out because of its simple solution process and high computational efficiency. Therefore, we chose the ERA to propose a parameter identification method for sub-synchronous oscillation of a power grid.
3. Identification of SSO Parameters of the Fitting-Based ERA
3.1. The Methodology of the ERA
Utilizing the synchrophasor model’s distinct features, the ERA formulates the Hankel matrix. Firstly, it constructs two shifted Hankel matrices and then derives the system matrix using the distinct interdependence linking the two translated Hankel matrices.
Therefore, two translated Hankel matrices must be formulated by using a synchrophasor sequence , which are denoted as and , and their expressions are as follows:
where represents the number of synchrophasors and each row and column in the Hankel matrix has time continuity.
According to Section 2.1, the synchrophasor model under SSO is formed by a linear combination of four modes. Therefore, the Hankel matrix is further decomposed, and it is expressed as follows. When k is zeri, the Hankel matrix is further decomposed by singular values [20], which are expressed as follows:
where the matrix is the eigenvalue matrix.
According to the characteristics between two shifted Hankel matrices, Hankel matrix can be expressed as shown in Equation (16):
where is a system matrix and .
Utilizing Equation (16) as a basis, the determination of the system matrix is facilitated by applying the subsequent formula:
Consequently, the acquisition of angular frequency values necessitates resolution of the matrix as the sole means.
3.2. Deficiencies of the Current ERA
The current ERA builds a Hankel matrix utilizing synchrophasor data in the complex plane, subsequently deriving the system matrix within the same complex domain. Determining the angular frequencies for four modes involves resolving the eigenvalues of the system matrix within the realm of complex numbers. Mathematically speaking, the current ERA method can exactly determine the subsynchronous oscillation parameters under ideal conditions. When calculating the eigenvalues associated with the system matrix in complex domains, we can obtain four eigenvalues for the system matrix which are conjugated in pairs.
However, in practical application, there will be various disturbances in the instantaneous signal. At this time, when the eigenvalue of the complex domain system matrix is directly solved, the eigenvalue of the obtained system matrix no longer satisfies the pairwise conjugate relationship, and the ideal situation for the distance of conjugation of a pair of eigenvalues is quite different. Therefore, the algorithm proposed in this paper improves this defect and considers the conjugate constraint of the angular frequency.
3.3. The Basic Idea of the Fitting-Based ERA
3.3.1. Solving the Angular Frequencies and
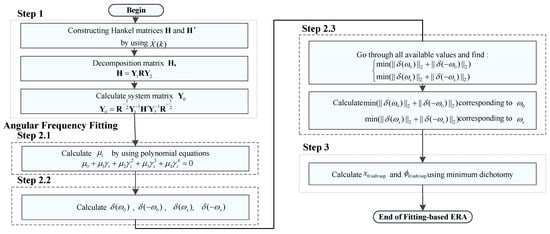
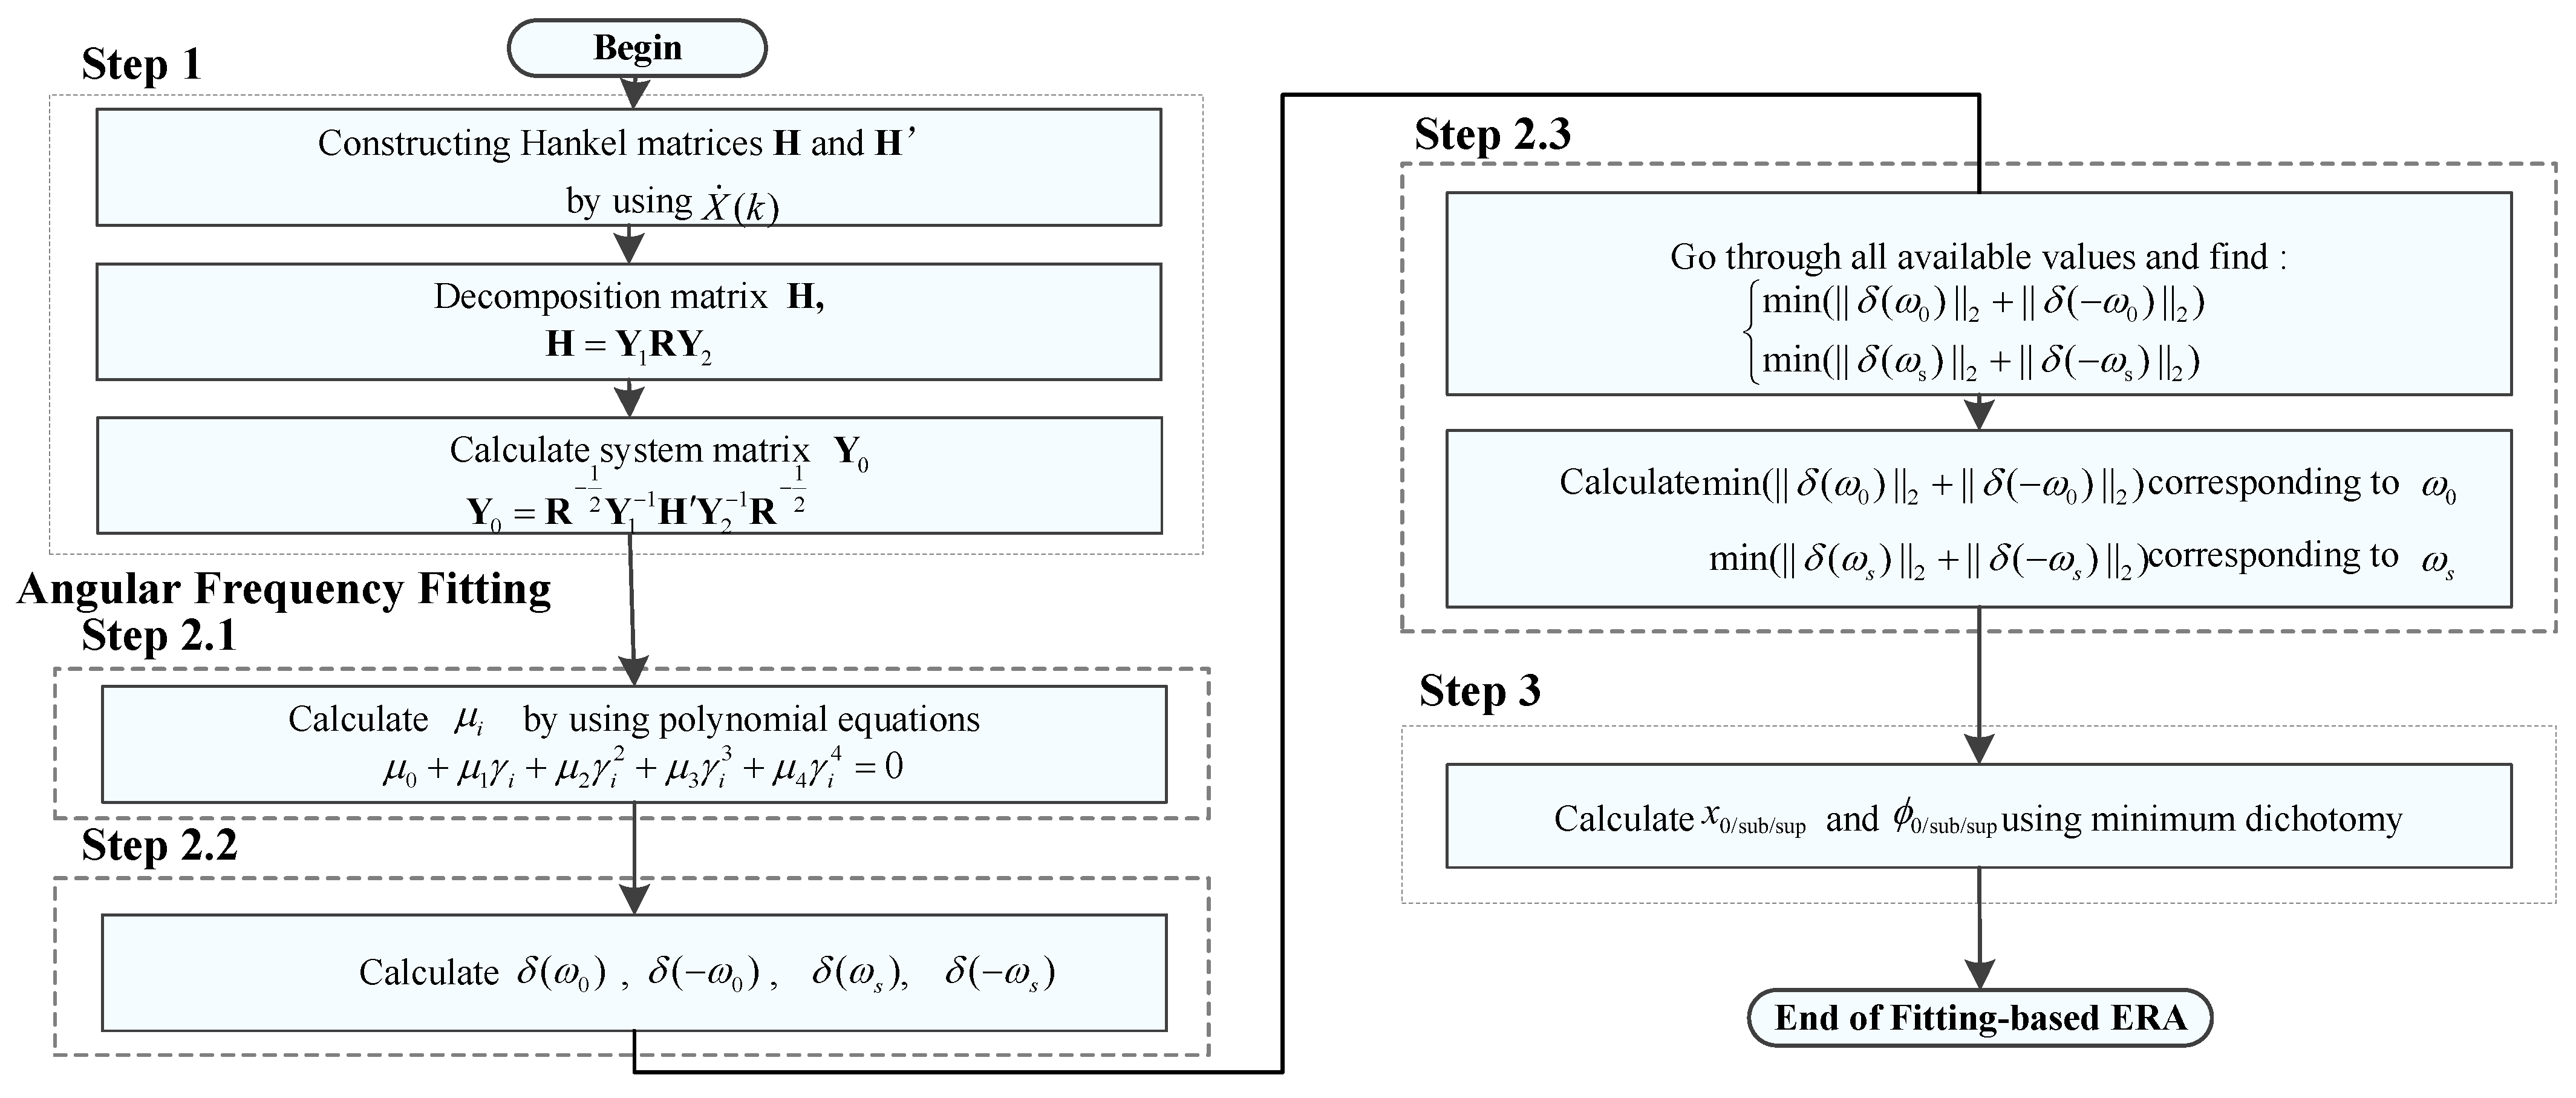
Based on the characteristic polynomial coefficients of the system matrix, the basic idea of the fitting-based ERA proposed in this paper is to establish the angular frequency fitting equation corresponding to the fundamental frequency and oscillation frequency. The spectral decomposition of reveals four eigenvalues. According to the principle of matrix decomposition, the four eigenvalues can be transformed into a characteristic polynomial equation. Two fundamental modes and two oscillation modes are considered, which ensures accuracy when solving and . Moreover, the flow chart of the algorithm in this paper is shown in Figure 1.
Figure 1.
Flowchart for fitting-based ERA.
Based on the properties of the characteristic polynomial, the characteristic polynomial equation of the system characteristic matrix can be obtained as follows:
where represents the characteristic polynomial coefficients of the system matrix.
Because the characteristic polynomial coefficients can be solved by the eigenvalue of the system matrix , they are equivalent, and thus can be used instead of to establish the subsequent angular frequency fitting equation. Moreover, in the case of model errors, calculated by has calculation errors. At this time, if the correct angular frequency or is substituted into Equation (18), the equation will no longer hold, and there will be residuals. Therefore, the angular frequency or can be accurately solved by searching for the smallest residuals.
Therefore, after obtaining the system matrix , we first calculate the characteristic polynomial coefficient of the system matrix and then establish the fitting equation of and according to as follows:
where , , and are residuals of the fitting equations.
The minimum value of the residual is found by fitting Equation (19). Thus, the value of the angular frequency is solved. Similarly, the minimum value of the residual is found by fitting Equation (20) so as to find the value of the angular frequency . Then, the values of four constant coefficients can be obtained with Equation (9), and Equation (10) can be utilized to additionally derive the specific frequencies, amplitudes and phases associated with the oscillation component.
The fitting equations for and take into account the conjugate constraints of and . Angular frequencies and with large errors can be eliminated by solving the minimum residuals corresponding to and , respectively. The and values acquired by means of this methodology conform to the conjugate constraints of and , respectively. Furthermore, they exhibit the closest proximity to the eigenvalues of the system matrix.
3.3.2. Solution of the SSO Parameters
Based on Section 3.3.1, the angular frequencies and of the fundamental component and oscillation component can be obtained. Subsequently, the comprehensive methodology for deriving the frequencies, magnitudes and phases of individual components is outlined as follows.
First, the four constants , , and are determined or resolved in accordance with Equation (21):
Second, , , and are solved for using Equations (8) and (10) by utilizing , and :
Subsequently, by utilizing Equations (4) and (8) in conjunction, the fundamental component’s frequency, amplitude and initial phase are ascertained, as demonstrated in Equation (23):
Finally, by integrating Equations (4) and (8) and , the frequencies, magnitudes and phases corresponding to both subsynchronous and supersynchronous oscillations are subsequently determined:
Up to this point, the comprehensive calculations pertaining to the determination of the frequencies, magnitudes and initial phases of the fundamental, subsynchronous and supersynchronous constituents of the synchrophasor have been thoroughly executed, marking the successful conclusion of the modal parameter characterization for the synchrophasor.
3.3.3. Limitations of the Fitting-Based ERA
In fact, the improved fitting-based ERA also has certain limitations. Because the improved algorithm uses the fitting equation of the angular frequency to solve for the angular frequency, it does not fully utilize the advantage of the ERA’s small calculation effort based on matrix decomposition. Although the method used in this algorithm to solve the quartic equation in one variable is not complicated and has little impact on the computing efficiency, can there be an algorithm which makes full use of the advantages of matrix decomposition in the future to reduce the amount of computation in the solving process? This will be a key research direction in the future.
4. Verification
The methodology for identifying subsynchronous oscillation parameters in power grids, leveraging the ERA as its foundation, underwent rigorous validation utilizing both artificially generated and authentic PMU data within the MATLAB R2021a environment. This comprehensive testing aimed to confirm not only the accuracy but also the practical feasibility and applicability of the proposed approach.
The utilization of synthetic PMU measurements as the cornerstone for testing primarily stems from pragmatic concerns. While real-world data undeniably hold immense value in power system analysis, they inherently struggle to encompass the full spectrum of frequencies and oscillation traits. The intricate and dynamic nature of power grid states and faults poses a challenge, rendering it arduous to comprehensively capture all instances of SSO data. A controllable data set is required to measure the capability and trustworthiness of algorithms comprehensively. Therefore, synthetic data which can accurately set oscillation parameters is selected to simulate complex SSO scenarios. This process facilitates the assessment of algorithm performance across diverse scenarios, ultimately verifying their accuracy and suitability for real-world deployment and thereby bolstering overall system reliability.
The adoption of genuine PMU data, being a vital component, is paramount, as it mirrors the intricate dynamic and oscillation behaviors of power systems in their operational states. Employing such data for algorithmic assessment enhances the precision in determining the algorithm’s practical applicability and feasibility in real-life contexts. Concurrently, utilizing genuine PMU data facilitates a profound comprehension of the power system’s dynamic traits, unveiling phenomena which may remain elusive in simulated environments and foster a superior grasp of operational protocols alongside potential hazards. However, it should be noted that actual measured PMU data may be affected by factors such as sensor errors and communication delays, which can have a certain impact on the accuracy and reliability of the data. In general, it is important to use actual PMU data measurements to validate the feasibility and practicality of algorithms in real-world scenarios.
4.1. Simulation Validation Utilizing Synthetic PMU Data
Using Equation (1) as the instantaneous signal model for generating simulated PMU data, we first set the initial parameters for the simulated PMU data. We set the rated frequency of the system equal to 50. Then, we set the fundamental frequency to be [49 49.5 49.7 50 50.5 51 51.5] Hz. The remaining parameters for the fundamental, subsynchronous and supersynchronous components are specified as follows: (, ) = (100, ), () = () and () = ().
During the verification process, the sampling frequency of instantaneous data was set at 1.6 kHz. Sampling the instantaneous data using DFT resulted in synthetic PMU data with an upload frequency of 100 Hz. In the process of determining the SSO characteristics through the application of a fitting-based ERA technique, a specified data segment 200 ms in duration was employed, which encompassed precisely 21 consecutive synchrophasor measurements for analysis.
Based on previous research [17], and have the greatest impact on the identification accuracy of the synchrophasor parameters under SSO. Therefore, using the control variables method, we let vary at intervals of 1 Hz within the range of [5, 45] Hz and vary at intervals of 1 within the range of [5, 100]. After generating PMU data under the above conditions, the synthetic PMU data were used for SSO parameter identification based on the fitting-based ERA method. To avoid randomness to a certain extent, each case was recalculated 50 times, and the central tendency was taken. Additionally, to evaluate the accuracy of the improved algorithm in determining SSO parameters within a noisy environment, we embedded zero-mean white noise into the model of instantaneous signals in Equation (1) for analysis. Drawing from [16], which states that the measured signal-to-noise ratio (SNR) of PMU data approximates to 45 dB, a noise condition of 40 dB was chosen for the simulation.
Table 1 presents the identification results of SSO parameters using the fitting-based ERA method (abbreviated as “F-ERA”) and the existing ERA method for comparison.
Table 1.
Conducted evaluation of the SSO parameter estimation errors for both the F-ERA and ERA (unit: %).
4.1.1. Absolute Deviations in Optimal Scenarios
According to the data in Table 1, under optimal scenarios, whether varies at an interval of 1 Hz within the range of [5, 45] Hz or varies at an interval of 1 within the range of [5, 100] HZ, the relative error of parameter identification of the fitting-based ERA was less than , which approximated the outcomes achieved by the conventional ERA utilizing 1 s and 200 ms data windows. Therefore, under optimal scenarios, the ERA both before and after improvement can better perform the SSO parameter identification task.
4.1.2. Absolute Deviations in Noise Scenarios
By adding white noise with a 40 dB SNR to the instantaneous signal, as can be seen in Table 1, regardless of whether varied at 1 Hz intervals within the range of [5, 45] Hz or varied at 1 Hz intervals within the range of [5, 100] HZ, the identification error of exceeded 5% when using the traditional ERA algorithm with 200 ms and 1 s time frames. The primary reason for this is that the paired association of the angular velocities and contenting and was not considered, leading to significant errors in fundamental wave parameter identification. Meanwhile, the existing ERA exhibited a significant identification error rate of nearly 8% for under the 200 ms data window and an even higher error rate exceeding 12% for . In contrast, the fitting-based ERA could control the relative error of the identification results to below 1.75% even with a 200 ms data window. Therefore, there is clear evidence that the fitting-based ERA provides more rigorous identification results for synchrophasor parameters under SSO conditions featuring a 40 dB SNR level than the existing ERA, validating the correctness and feasibility of this algorithm for identifying synchrophasor parameters under SSO conditions.
4.2. Simulation Validation Utilizing Authentic PMU Data
To conclusively assess the effectiveness of the fitting-based ERA method in identifying various parameters of synchrophasors under SSO, simulation analysis was conducted, leveraging authentic PMU recordings gathered during a real SSO event within the North China Power Grid’s operational environment [17].
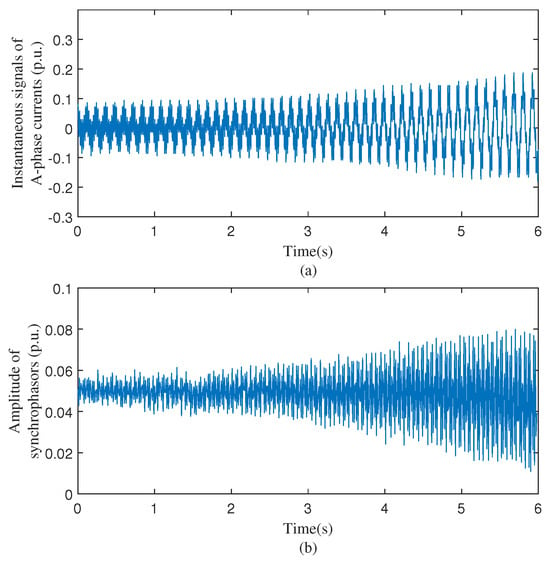
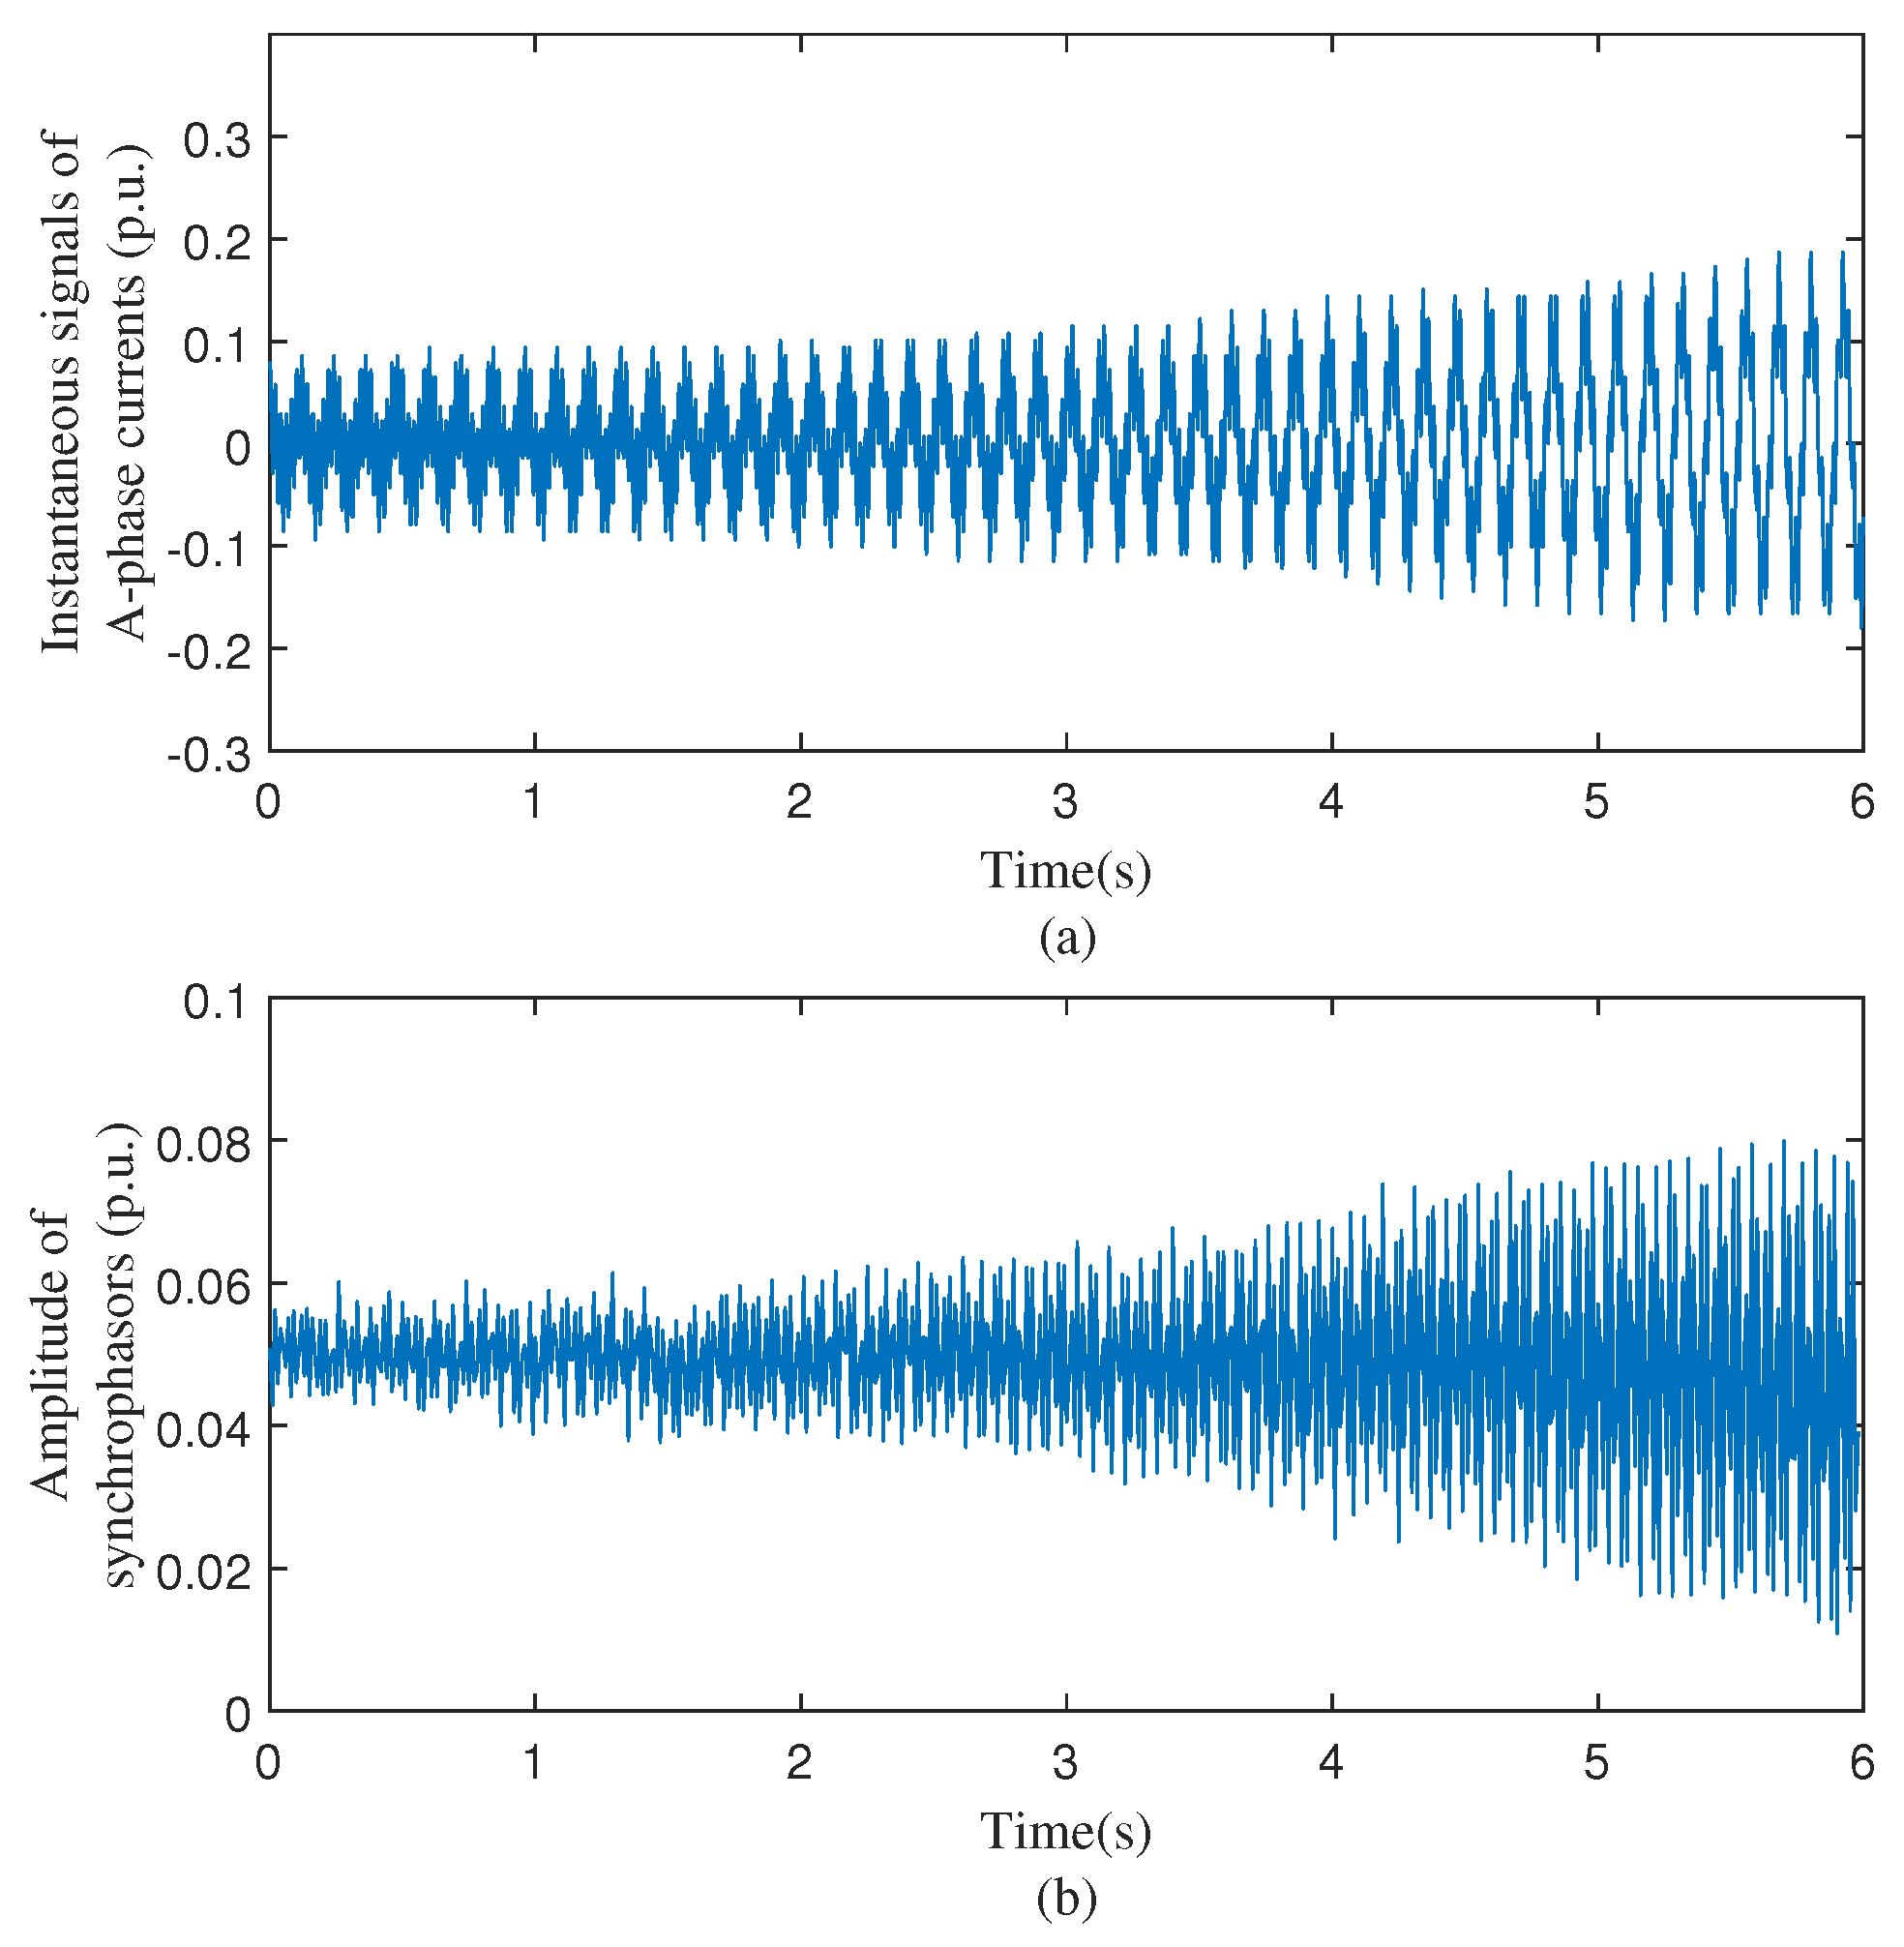
The real-time current signal and the magnitudes of the synchrophasor quantities, as derived from the authentic PMU measurements, are illustrated in Figure 2.
Figure 2.
Instantaneous current signal and synchrophasor amplitudes for authentic PMU data. (a) Instantaneous currents. (b) Amplitudes of synchrophasors.
As depicted in Figure 2, the targeted 6 s data window, functioning as the cornerstone of our simulation and grounded in authentic PMU recordings, revealed exceptionally swift fluctuations in SSO activity. This rapid fluctuation reflects the complexity of the dynamic behavior in relation to the energy grid, posing challenges for monitoring and analyzing system stability.
In this paper, the presented fitting-based ERA approach identified a 200 ms data segment for analysis. Additionally, a DFT algorithm utilizing interpolation and employing a 2 s data frame for processing was implemented, theoretically offering higher accuracy in its identification results. Therefore, the identification results from a DFT algorithm utilizing interpolation and employing a 2 s data frame were used as a reference benchmark for assessing the identification accuracy of other algorithms. Furthermore, the identification results of the SSO parameters using the existing ERA method with a data window length of 1 s were also compared.
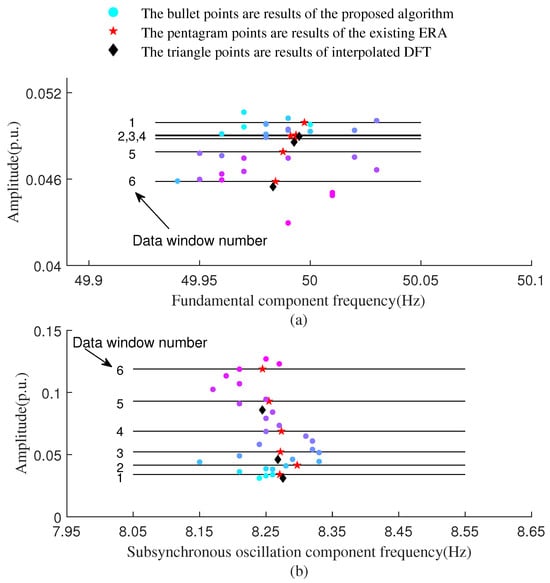
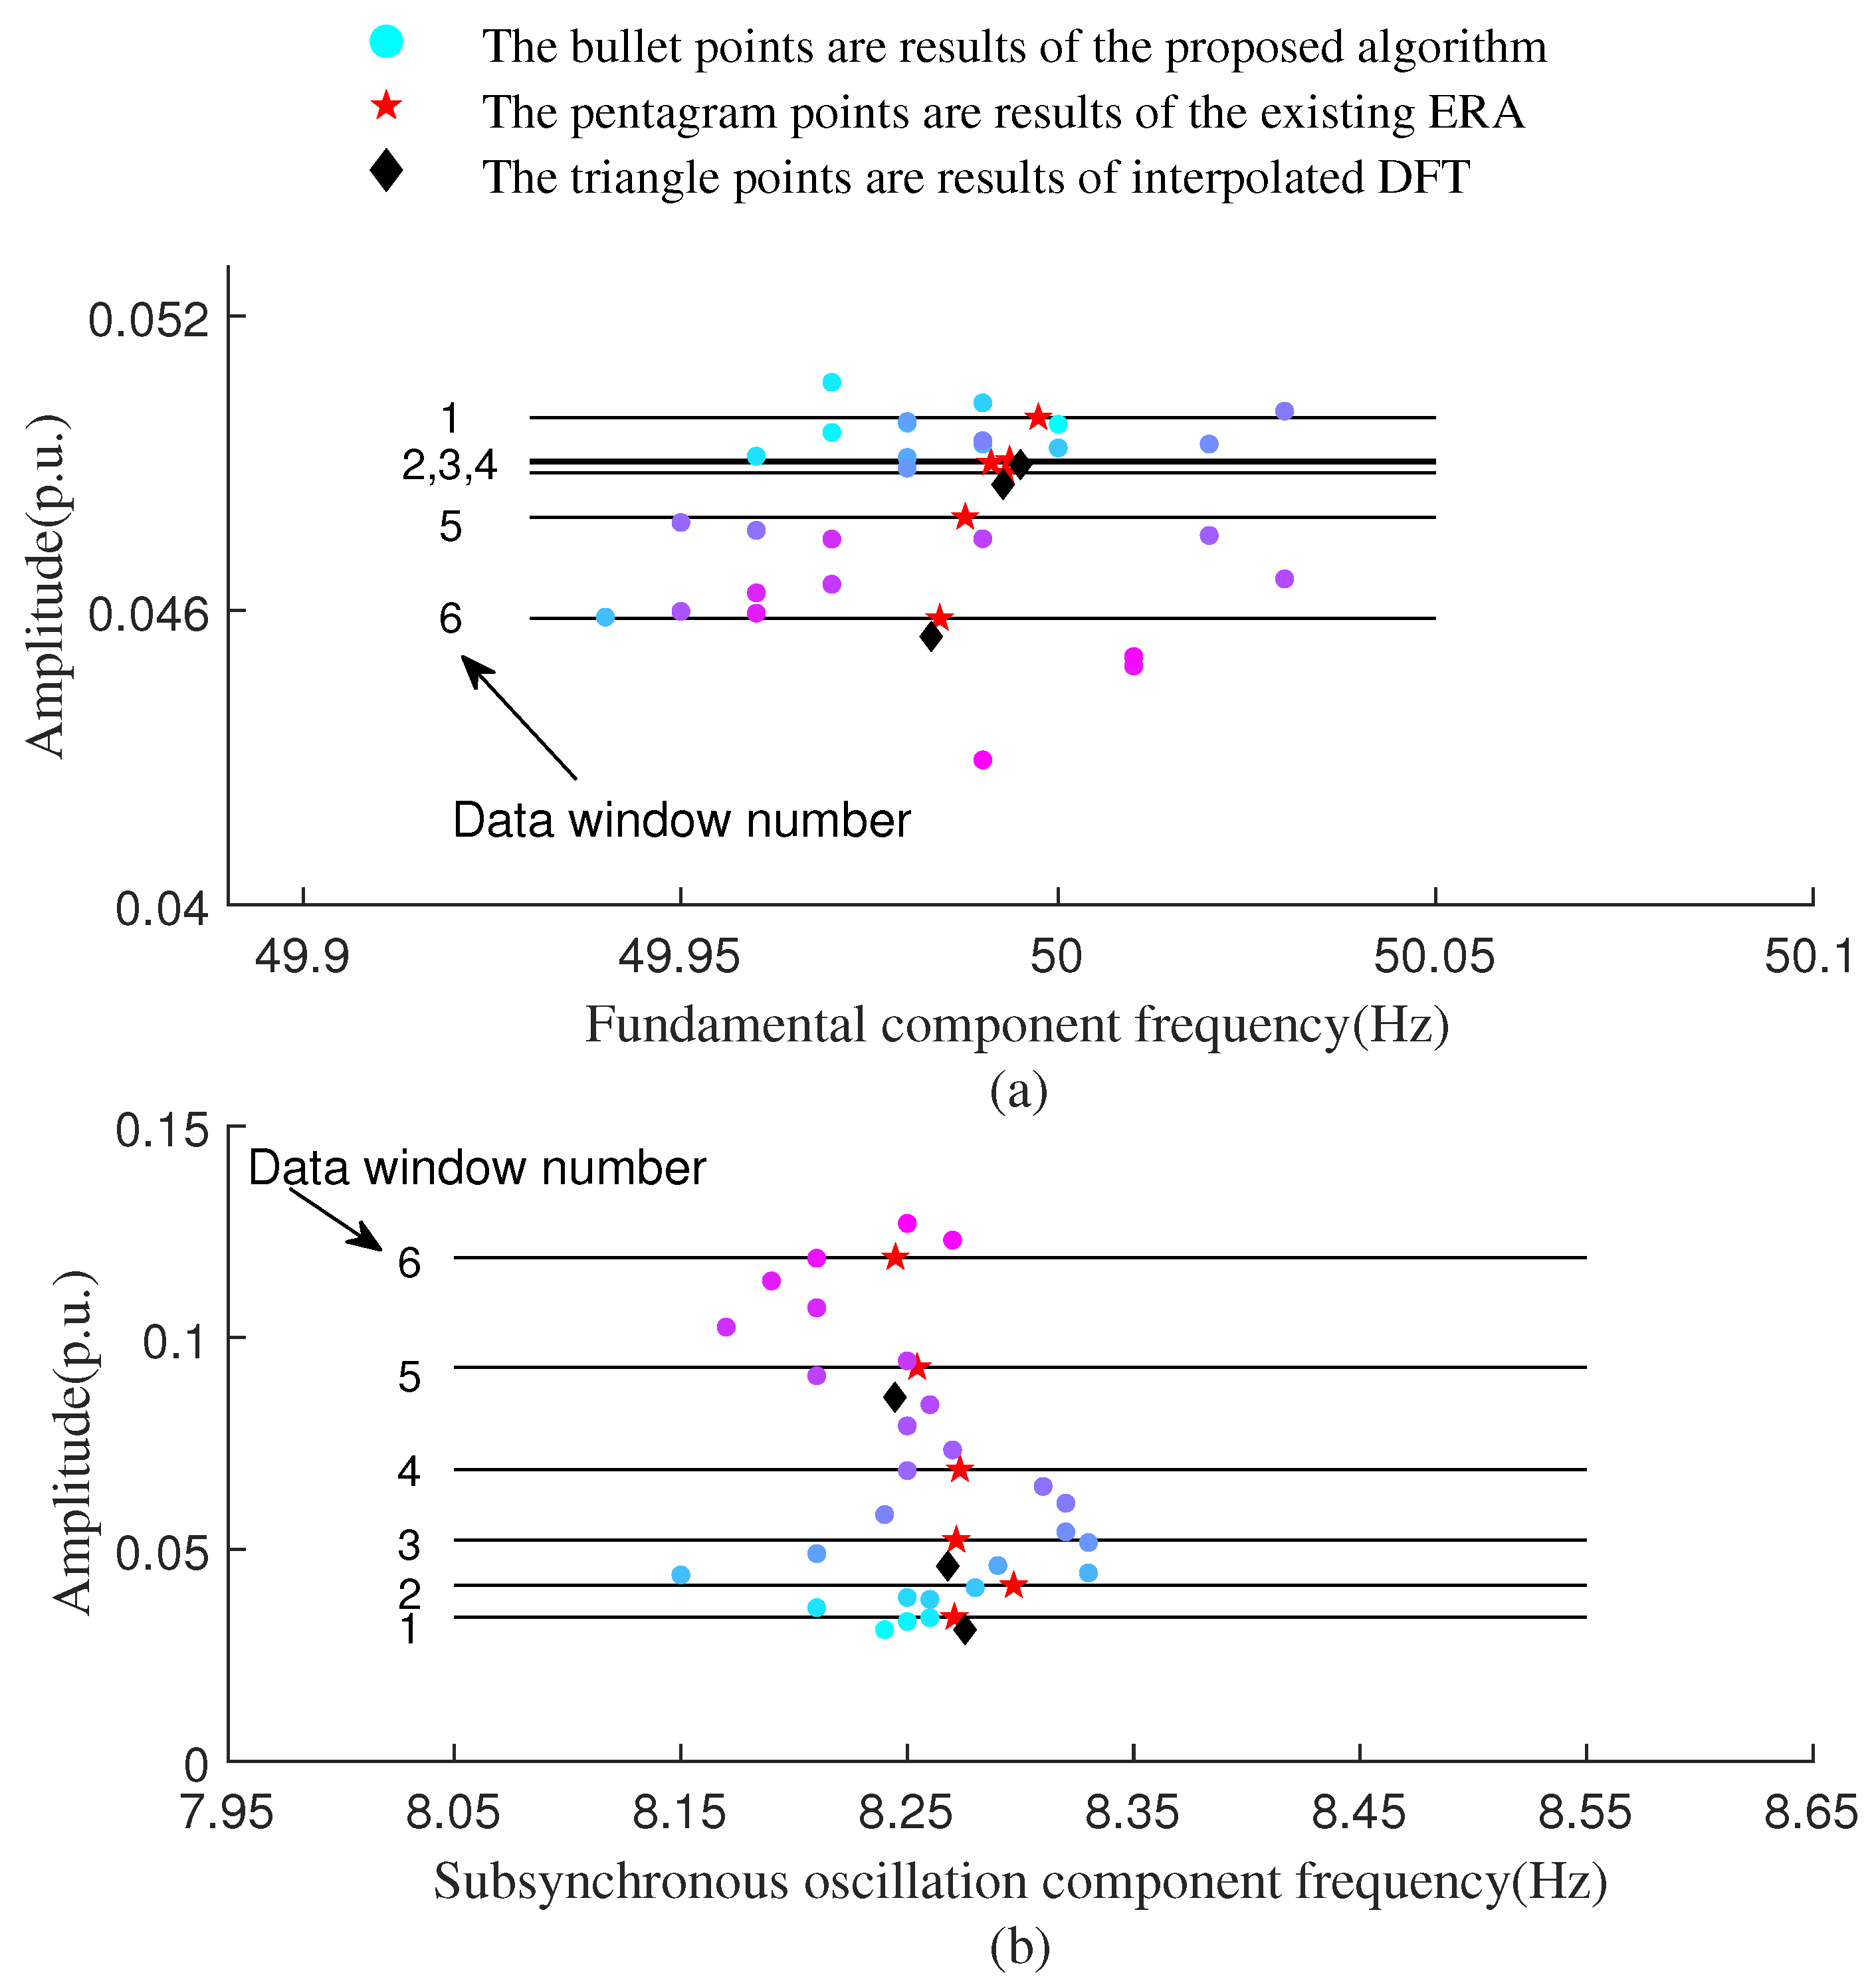
Using the three approaches, the recognition outcomes of the synchrophasor parameters under SSO are presented in Figure 3. Gradient fill points resulted from the introduced algorithm, with blue and rose red representing the start and end times, respectively. Given that the subsynchronous and supersynchronous elements formed a coupled pair, the precision of identifying the supersynchronous element could be roughly mirrored by the outcomes of recognizing the subsynchronous counterpart. Consequently, the results pertaining to the supersynchronous element’s identification are excluded from further discussion.
Figure 3.
Identified results of frequency and amplitude for actual measured PMU data case. (a). Fundamental component frequency (b). Subsynchronous oscillation component frequency.
4.2.1. The Recognition Outcomes of the Fundamental Elements
Figure 3a depicts the parameter recognition outcomes of the fundamental elements obtained by three approaches. The figure clearly illustrates that the recognition outcomes of from the fitting-based ERA were between 49.94 Hz and 50.03 Hz, and the identification results of were between 0.0430 p.u. and 0.0506 p.u. The difference in identification results compared with the existing ERA and interpolated DFT algorithm was insignificant. Theoretically, as the length of the data window increases, a greater amount of information is extracted, leading to more precise identification results, but the real-time performance will be worse. The existing ERA and interpolated DFT algorithm employ data window durations of 1 s and 2 s, respectively. In contrast, the fitting-based ERA can obtain identification results with similar accuracy using only a 200 ms data window. Using a 200 ms ultra-short data window, the ERA approach, rooted in fitting techniques, facilitates the dynamic observation and analysis of SSO activity in an electrical grid, ensuring continuous monitoring capabilities.
4.2.2. The Recognition Outcomes of the Subsynchronous Element
Figure 3b presents the parameter recognition outcomes of the subsynchronous component acquired by the three approaches. Upon examination of the figure, it becomes apparent that the recognition outcomes of by the fitting-based ERA were between 8.15 Hz and 8.33 Hz, while the recognition outcomes of were between 0.0311 p.u. and 0.1270 p.u. The recognition outcomes of the fitting-based ERA were comparable to those of the existing ERA and interpolated DFT algorithm. However, the fitting-based ERA exhibited more details, reflecting the rapid time-varying characteristics of and . During the rapid variation phase of SSO, the fitting-based ERA better demonstrated the real-time nature of SSO. Therefore, the fitting-based ERA can achieve relatively accurate dynamic monitoring of the SSO in a power grid under a 200 ms data window.
5. Conclusions
In the existing ERA parameter identification process, the conjugate constraint relationship of the angular frequencies is not fully considered, which leads to a decrease in the accuracy of the SSO parameter identification results in actual scenes. Using the ERA’s advantages, such as easy solutions, low computational complexity, and anti-noise solid capability, a fitting-based ERA parameter identification method for SSO is proposed, enabling dynamic real-time monitoring of SSO in the modern power system. However, the fitting-based ERA successfully addresses this issue by introducing an angular frequency fitting equation to solve the conjugate constraints of these angular frequencies, making the parameter identification results more precise and reliable and thereby realizing the ability to use a 200 ms data window for SSO parameter identification. This paper also validated the fitting-based ERA method using synthetic and actual PMU data. The validation results indicate that compared with the existing ERA, the fitting-based ERA can achieve accurate parameter identification results with a 200 ms data window, enhancing its application value in SSO analysis of power systems.
Author Contributions
Conceptualization, G.C., X.Z., Y.L., F.Z. and H.S.; methodology, G.C., X.Z., Y.L., F.Z. and H.S.; validation, G.C. and X.Z.; data curation, G.C. and X.Z.; formal analysis, Y.L. and F.Z.; investigation, H.S.; writing—original draft preparation, G.C. and Y.L.; writing—review and editing, G.C.; visualization, X.Z.; supervision, F.Z.; project administration, X.Z.; funding acquisition, X.Z. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the Science and Technology Project of the State Grid Corporation of China under grant number 521997230001, and the APC was funded by grant number 521997230001.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Data are contained within the article.
Conflicts of Interest
The authors declare that they have no known competing financial interests or personal relationships which could have appeared to influence the work reported in this paper. Gang Chen, Xueyang Zeng and Huabo Shi are employees of the State Grid Sichuan Electrical Power Research Institute, who provided funding and technical support for this work. The funder had no role in the design of the study; in the collection, analysis, or interpretation of data, in the writing of the manuscript, or in the decision to publish the results.
References
- Zhao, S.; Wang, N.; Li, R.; Gao, B.; Shao, B.; Song, S. Sub-synchronous control interaction between direct-drive PMSG-based wind farms and compensated grids. Int. J. Electr. Power Energy Syst. 2019, 109, 609–617. [Google Scholar] [CrossRef] [Scilit]
- Huang, B.; Xin, Q.; Zhao, X.; Yuan, Z.; Li, H.; Feng, J. Coupling Characteristics of Subsynchronous Oscillation Frequencies in Multi-Renewable Power Plants Integrated to Power System. In Proceedings of the 2023 IEEE Sustainable Power and Energy Conference (iSPEC), Chongqing, China, 29–30 November 2023; pp. 1–6. [Google Scholar]
- Hongli, J.; Shiying, M.; Ruihua, S.; Zutao, X. Research on Subsynchronous Interaction between direct-drive PMSG based Wind Farm and Static Var Generator. In Proceedings of the 2020 5th Asia Conference on Power and Electrical Engineering, Chengdu, China, 4–7 June 2020; pp. 1160–1165. [Google Scholar]
- Xie, X.; Zhan, Y.; Liu, H.; Li, W.; Wu, C. Wide-area monitoring and early-warning of subsynchronous oscillation in power systems with high-penetration of renewables. Int. J. Electr. Power Energy Syst. 2019, 108, 31–39. [Google Scholar] [CrossRef] [Scilit]
- Patil, V.S.; Thakre, M.P. Grid Integration of the Wind Power Generation and its Potential Impact on Sub-Synchronous Oscillation. In Proceedings of the 2020 International Conference on Power, Energy, Control and Transmission Systems (ICPECTS), Chennai, India, 10–11 December 2020; pp. 1–7. [Google Scholar]
- Mohale, V.; Chelliah, T.R. Sub Synchronous Oscillation in Asynchronous Generators Serving to Wind and Hydro Power Systems—A Review. In Proceedings of the 2021 IEEE Industry Applications Society Annual Meeting (IAS), Vancouver, BC, Canada, 10–14 October 2021; pp. 1–7. [Google Scholar]
- Li, H.; Abdeen, M.; Chai, Z.; Kamel, S.; Xie, X.; Hu, Y.; Wang, K. An Improved Fast Detection Method on Subsynchronous Resonance in a Wind Power System With a Series Compensated Transmission Line. IEEE Access 2019, 7, 61512–61522. [Google Scholar] [CrossRef] [Scilit]
- Shair, J.; Xie, X.; Yang, J.; Li, J.; Li, H. Adaptive Damping Control of Subsynchronous Oscillation in DFIG-Based Wind Farms Connected to Series-Compensated Network. IEEE Trans. Power Deliv. 2022, 37, 1036–1049. [Google Scholar] [CrossRef] [Scilit]
- Khalilinia, H.; Venkatasubramanian, V. Subsynchronous Resonance Monitoring Using Ambient High Speed Sensor Data. IEEE Trans. Power Syst. 2016, 31, 1073–1083. [Google Scholar] [CrossRef] [Scilit]
- Netto, M.; Mili, L. A Robust Prony Method for Power System Electromechanical Modes Identification. In Proceedings of the 2017 IEEE Power and Energy Society General Meeting PESGM, Chicago, IL, USA, 16–20 July 2017. [Google Scholar]
- Khazaei, J.; Fan, L.; Jiang, W.; Manjure, D. Distributed Prony analysis for real-world PMU data. Electr. Power Syst. Res. 2016, 133, 113–120. [Google Scholar] [CrossRef] [Scilit]
- Rauhala, T.; Gole, A.M.; Jarventausta, P. Detection of Subsynchronous Torsional Oscillation Frequencies Using Phasor Measurement. IEEE Trans. Power Deliv. 2016, 31, 11–19. [Google Scholar] [CrossRef] [Scilit]
- Wall, P.; Dattaray, P.; Jin, Z.; Mohapatra, P.; Yu, J.; Wilson, D.; Hay, K.; Clark, S.; Osborne, M.; Ashton, P.M.; et al. Deployment and demonstration of wide area monitoring system in power system of Great Britain. J. Mod. Power Syst. Clean Energy 2016, 4, 506–518. [Google Scholar] [CrossRef] [Scilit]
- Ma, Y.; Huang, Q.; Zhang, Z.; Cai, D. Application of Multisynchrosqueezing Transform for Subsynchronous Oscillation Detection Using PMU Data. IEEE Trans. Ind. Appl. 2021, 57, 2006–2013. [Google Scholar] [CrossRef] [Scilit]
- Zhang, F.; Cheng, L.; Gao, W.; Huang, R. Synchrophasors-Based Identification for Subsynchronous Oscillations in Power Systems. IEEE Trans. Smart Grid 2019, 10, 2224–2233. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.; Zhang, J.; Xie, X.; Xiao, X.; Gao, B.; Wang, Y. Interpolated DFT-Based Identification of Sub-Synchronous Oscillation Parameters Using Synchrophasor Data. IEEE Trans. Smart Grid 2020, 11, 2662–2675. [Google Scholar] [CrossRef] [Scilit]
- Zhang, F.; Li, J.; Liu, J.; Gao, W.; He, J. An Improved Interpolated DFT-Based Parameter Identification for Sub-/Super-Synchronous Oscillations With Synchrophasors. IEEE Trans. Power Syst. 2023, 38, 1714–1727. [Google Scholar] [CrossRef] [Scilit]
- Almunif, A.; Fan, L.; Miao, Z. A tutorial on data-driven eigenvalue identification: Prony analysis, matrix pencil, and eigensystem realization algorithm. Int. Trans. Electr. Energy Syst. 2020, 30, e12283. [Google Scholar] [CrossRef] [Scilit]
- Abhinav, K.; Rai, P.; Prakash, A.; Parida, S.K. Comparative Assessment of Prony Analysis and Eigensystem Realization Algorithm for Forced Oscillation Detection and Mode Estimation Considering PMU Noise. In Proceedings of the 2023 IEEE 3rd International Conference on Smart Technologies for Power, Energy and Control (STPEC), Bhubaneswar, India, 10–13 December 2023; pp. 1–6. [Google Scholar]
- Zhang, X.; Zhang, F.; Gao, W.; He, J. Improved Subsynchronous Oscillation Parameter Identification with Synchrophasor Based on Matrix Pencil Method in Power Systems. J. Mod. Power Syst. Clean Energy 2024, 12, 22–33. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Jiang, X.; Xie, X.; Yang, X.; Xiao, X. Identifying Sources of Subsynchronous Resonance Using Wide-Area Phasor Measurements. IEEE Trans. Power Deliv. 2021, 36, 3242–3254. [Google Scholar] [CrossRef] [Scilit]
- Tu, Y.; Li, M.; Wu, Q.; Ji, T. Sub-synchronous Oscillation Source Localization Algorithm Based on Matrix Pencil Method and Oscillation Power. In Proceedings of the 2023 6th International Conference on Energy, Electrical and Power Engineering (CEEPE), Guangzhou, China, 12–14 May 2023; pp. 761–765. [Google Scholar]
- IEEE Std C37.118.1-2011 (Revision of IEEE Std C37.118-2005); IEEE Standard for Synchrophasor Measurements for Power Systems. 2011; pp. 1–61. Available online: https://home.agh.edu.pl/~turcza/pmu/C371181-2011.pdf (accessed on 11 August 2024).

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).