


Abstract
Linear tool path is widely used in high-speed NC machining. However, the geometrical discontinuity of the corner between the linear tool paths will lead to fluctuations in speed, acceleration and jerk, which can excite machinery vibration and reduce the machining efficiency and surface quality. To solve these problems, a novel corner smoothing method based on error feasible area and curvature optimization is proposed in this paper. Compared with most traditional corner smoothing methods using higher-order curves with all control points lying in the straight segment and inside of the tool path, the proposed method constructs B-spline transition curves with smaller curvatures to smooth the corners by reasonably distributing the curve control points inside and outside the straight line segment of the tool path (i.e., error feasible area). Furthermore, the corner transition curve is optimized by the minimum curve curvature extreme to improve the smoothness of the corner transition curve and reduce fluctuation in the kinematic profiles while respecting the G3 continuity (i.e., curvature-smooth), transition length limits and the uniqueness of curvature extremum. Finally, the simulation results show that the proposed method can reduce the curvature value and improve the smoothness of the curve and the minimum transitional velocity of the corner, which means that it can enhance machining efficiency and weaken machining vibration. The feasibility and effectiveness of the method are also verified.
1. Introduction
With the development of manufacturing technology, the requirement of machining efficiency and quality is becoming more and more important in the field of molds, impellers, aerospace and other complex parts [1]. Some commercial computer-aided design (CAD)/computer-aided manufacturing (CAM) software is also widely used to generate the tool path of complex parts, which is usually represented by straight-line segments [2,3]. However, due to the discontinuity of the tangent and curvature of the corner point between the linear tool paths, the speed, acceleration and jerk are discontinuous and the phenomena of acceleration and deceleration occur frequently. These factors will reduce the machining efficiency and produce violent vibration, which will also affect the machining quality and accuracy [4]. Therefore, it is of great significance to improve the smooth transition performance of the linear tool path.
In recent years, the corner smoothing method has been an effective method for achieving a high-speed continuous motion along a linear tool path, which has been widely studied. Pessles et al. [5] and Yang KM et al. [6] inserted an arc in the middle of the double linear tool path to make the tool path reach G1 continuity (i.e., speed-continuous). Subsequently, higher-order curves, such as Bezier, B-spline, PH or other curves were used to smooth corners and achieve G2 continuity (i.e., curvature-continuous), which can obtain good acceleration characteristics and low machining vibration. Bi et al. [7] developed a curvature smoothing algorithm based on a cubic Bezier curve to smooth the linear tool path of high-speed machining. This method realized G2 continuity and improved the feed speed. A similar curve with eight control points lying in the straight segment and inside the tool path was constructed to smooth the linear tool path in Du et al. [8] and they further optimize the curvature variation energy (CVE) to obtain good motion performance. The similar distribution of control points also appears in the following literature. Pateloup et al. [9] utilized triple B-spline to connect adjacent liner tool paths and achieve G2 continuity. The accuracy of the tool path and the smoothness of the feed speed were improved. Zhang et al. [10], Zhao et al. [11] and Han et al. [12] also used the same B-spline for realizing smaller curvature extrema to increase the transition speed. Sencer et al. [13] used quintic B-spline to smooth the path corners to ensure G2 continuity and optimal curvature. Farouki [14] developed a corner smoothing algorithm with G2 continuity based on the quintic PH curve. Shi et al. [15] also used the quintic PH curve to smooth the corners of a three-axis tool path, which can accurately limit the approximation error. Huang et al. [16] applied clothoid splines to develop a novel corner smoothing method with G2 continuity.
In addition, some scholars [17,18,19,20,21] found that there are potentials of the G3 (i.e., curvature-smooth) continuous tool path in suppressing machining vibration in experiments. Fan et al. [17] used two quartic Bezier curves to obtain a G3 continuous tool path where the curvature variation energy was optimized and the G3 tool path could generate smaller jerk than a G2 tool path. Similarly, in our previous work, we introduced a method of generating a G3 continuous tool path from a symmetric Bezier curve [18]. Tulsyan et al. [19] and Zhang et al. [20] applied quintic B-spline curves to obtain tool paths with G3 continuity. An analytical NURBS curve was inserted into the corners between linear segments for improving the smoothness of the linear toolpath and the machining efficiency [21]. In addition, others also extend the smoothing methods with G3 continuity to four-axis and five-axis tool paths [22,23,24]. Hu et al. [22,23] successfully developed a quintic PH spline to obtain a G3 continuous smoothing toolpath. Sun et al. [24,25] used the Bezier curve to construct a G3 continuous tool path in five-axis machining. This literature also verifies that a G3 continuous path can generate smoother speed and acceleration curves, and fluctuation in the acceleration and jerk profiles is effectively constrained to obtain good machining quality.
From the above related literature, we know that a transition curve with better curvature performance can enhance machining efficiency and surface quality. When constructing the corner transition curve, the main feature of these methods is that the control points are located in the straight segment and inside between the linear tool paths and the error constraint, mainly referring the maximum error of the midpoint of a corner between linear tool paths. To obtain the smaller curvature extreme of the corner transition curve, Sun et al. [26] developed a method of connecting the linear tool path with nine control points, which lay two control points outside the straight segment of the tool path, but this method only ensured G2 continuity. This also shows that there is still potentiality for the decrease in curvature extreme value and the improvement of smoothness at the corners. According to the above discussion, in order to ensure the surface quality and machining efficiency of the workpiece, this study reasonably determines all control points of the curve within the error feasible area of the tool path, that is, all control points can be distributed inside and outside the straight line segment of the tool path. Moreover, the curvature will be further optimized and the G3 continuous tool path can be obtained.
2. B-Spline Corner Smoothing Method
This section introduces a corner smoothing method using B-spline to generate continuous smooth motion and improve machining efficiency.
2.1. B-Spline Curve
The B-spline curve
is applied to smooth the corner between the linear tool paths, which can be defined as follows [27]:
where and represent the number of control points and the order of B-spline, respectively. They are set as 9 and 4, respectively. The knot vector is constructed as [0 0 0 0 0 1/5 2/5 3/5 4/5 1 1 1 1 1]. The basic functions are given as:
where 0/0 = 0.
Additionally, the B-spline curve can be simplified as:
where is a polynomial, which can be deduced from the basis function . The detailed descriptions are given in Appendix A.
The derivative of B-spline can be expressed as:
In the process of moving along the transition curve , the velocity , acceleration and jerk are typical kinematic parameters, whose vector form can be expressed:
where
In Equation (7), and denote time, arc length and curvature, respectively. As shown in Equation (7), the actual machine motion along the tool path is related to the profiles of the kinematic parameters (i.e., , and ) and the continuity of geometric parameters (i.e., and ). Therefore, in order to enhance the machining efficiency, it is necessary to strengthen the smoothness of the tool path.
For convenience of description, the control point of the transition curve in the multi segment linear tool path can be given as , represents the number of corners. In order to obtain the control points, the error feasible area, G3 continuity and curvature optimization are discussed as follow.
2.1.1. Error Feasible Area
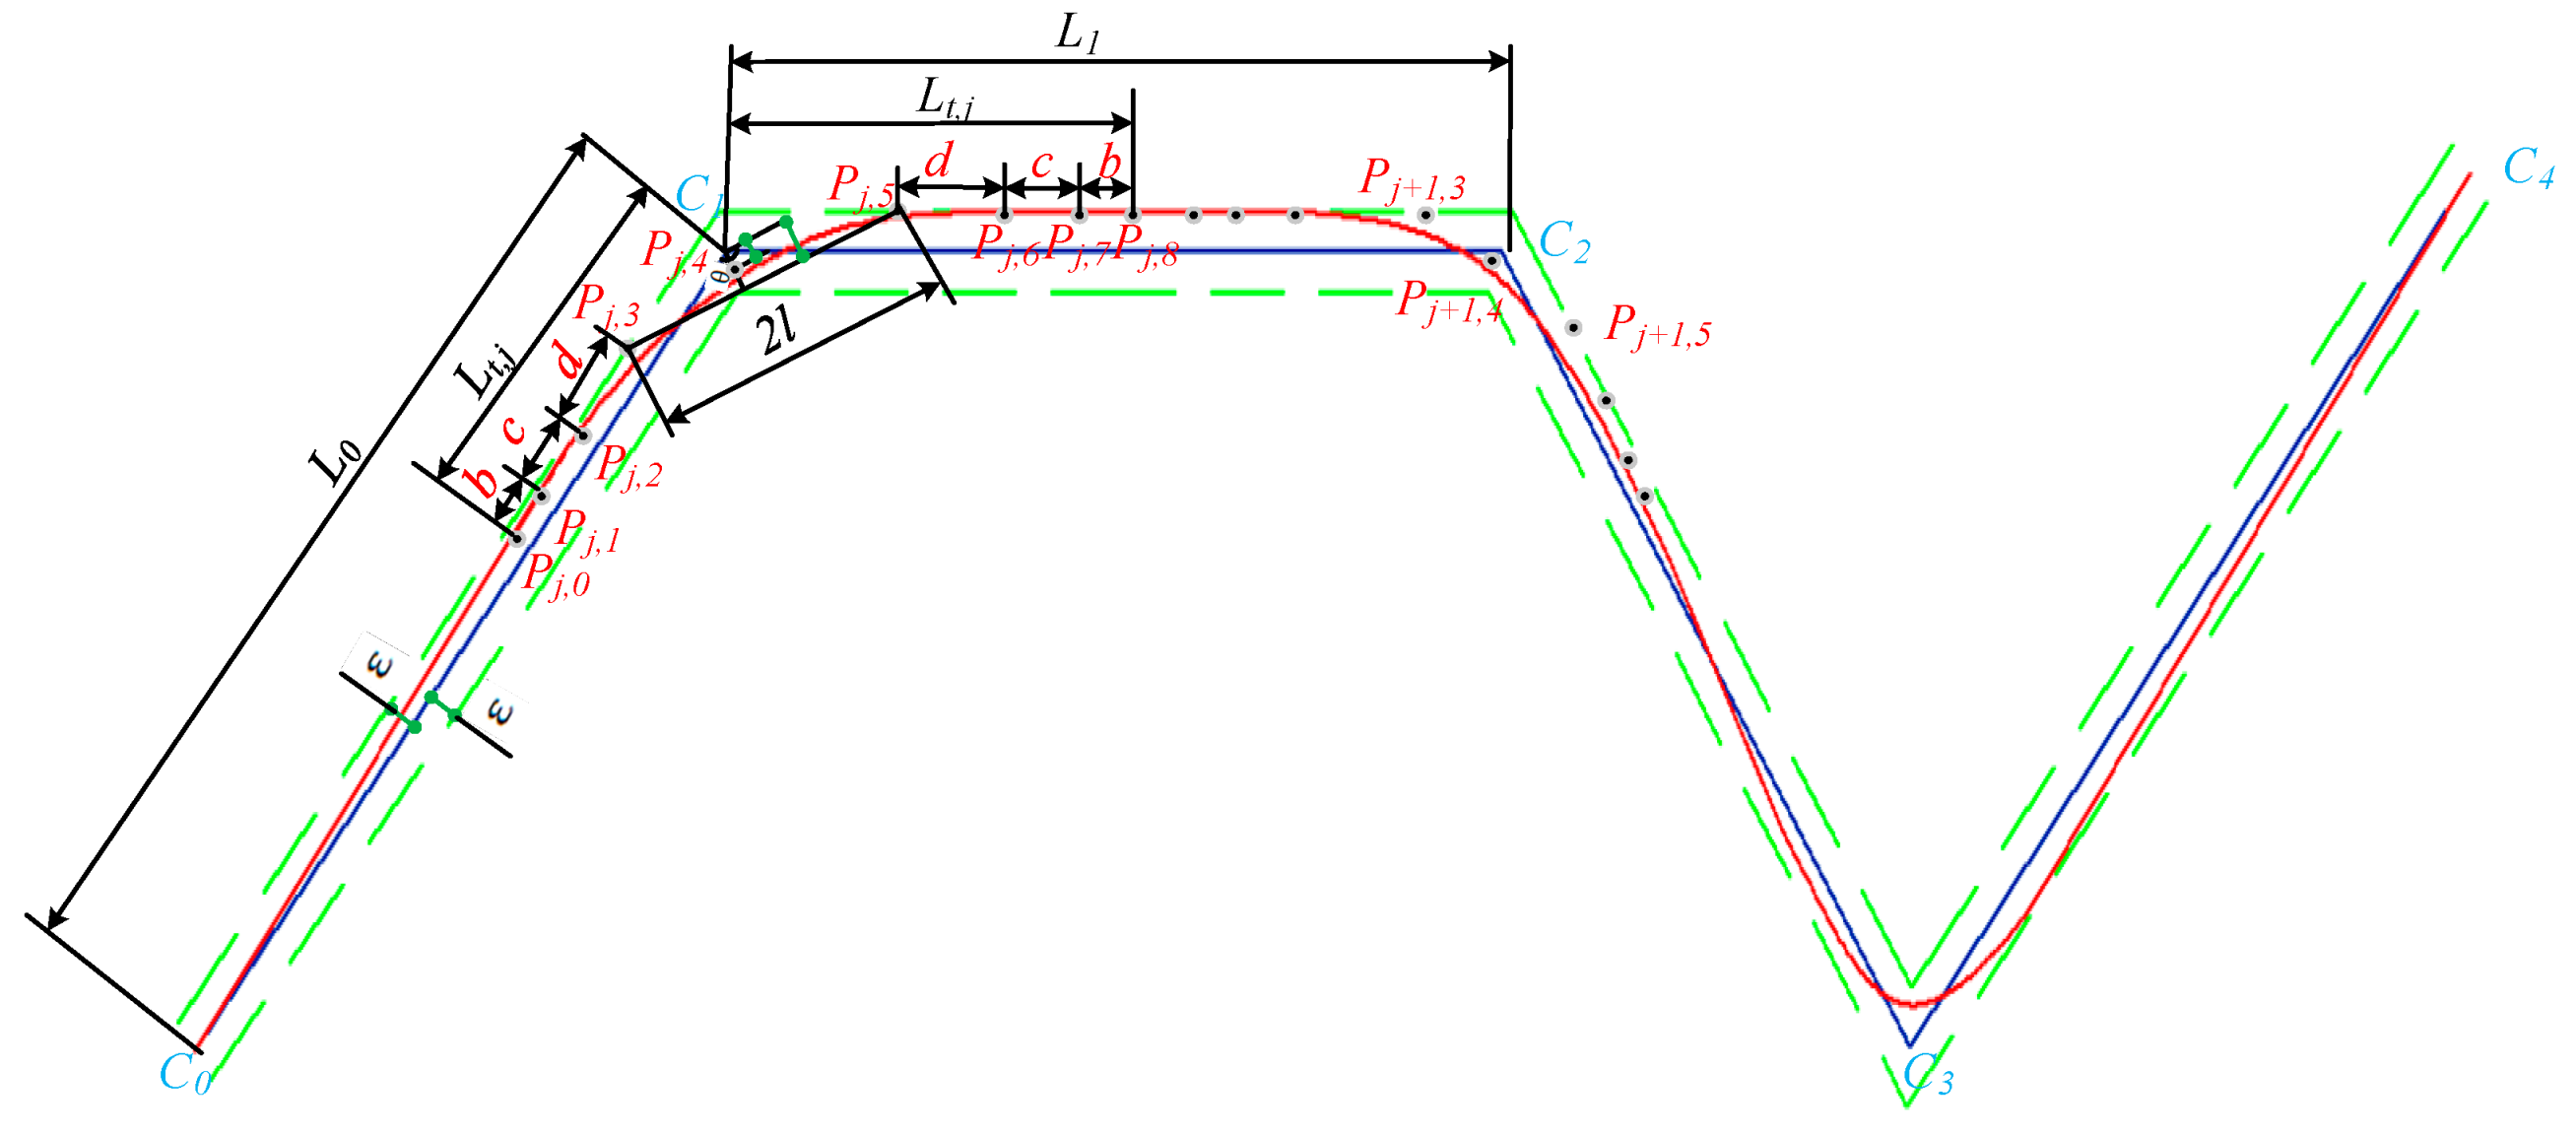
As shown in Figure 1, represents a linear tool path. The transition allowable error denotes the distance between the dotted line and the tool path. The area between two dashed lines is defined as the error feasible area. is the angle between the unit vector and . , , and . To achieve the allowable error of tool path corner transition, the reconstructed tool path should be within the error feasible area. Depending on the convex hull characteristics and symmetry of B-spline, nine control points of the corner transition curve must be within the error feasible area. Therefore, is located the angular bisector of . and are located at the boundary of error feasible area, respectively. and . can be expressed as:
Figure 1.
The distribution of corner-smoothing curve.
In order to obtain better corner smoothness, the control points , and lie on the linear segment ; , and lie on the linear segment . Additionally, when , . Meanwhile, when , . Thus, the control points of B-spline are calculated as follows:
2.1.2. G3 Continuity
In Figure 1, two linear tool paths are connected using the B-spline at junction points and . , , , and , , lie on the line segment, respectively. As mentioned above, the B-spline is 4th order with nine control points to keep G3 continuity at (0, 1). Since the derivative of the straight line segment is 0 at the connection points, the corresponding derivative of the B-spline should be 0 to obtain G3 continuous tool path. That is,
where
By mathematic calculation, the sufficient conditions for the establishment of Equations (12) and (13) can be given:
For corner smoothing B-spline curve, the derivatives of curve parameter with respect to arc length can be described as follows.
From Equations (18) to (20), it can be seen that the establishment of Equation (16) will lead to the establishment of Equation (17). Substituting Equations (5) and (6) into Equation (16) yields:
Solving Equation (21) obtains,
2.1.3. Corner Transition Length Constraint
As seen in Figure 1, the corners are smoothed by applying B-spline, where denotes the transition length, which is expressed as:
To avert the overlap of the two corners transition curves, the corners transition length should satisfy the following conditions. That is
2.2. Curvature Optimization
In the machining process of the corners, the minimum transition velocity of corner is the most important factor that limits the machining efficiency, and also affects the acceleration and jerk . According to the literature [28,29], the velocity can be expressed as
As can be shown in Equation (25), the velocity is inversely proportional to the curvature. In order to improve the velocity, smaller curvature should be ensured to obtain higher machining efficiency. In addition, when the curvature reaches the extreme value, it also means that the velocity reaches the extreme value. The increase in the number of curvature extremes leads to the redundant deceleration or acceleration at the corner, which can cause violent fluctuation in speed and the vibration of machining. Therefore, to obtain the unique curvature extremum, the curvature of transitional curve should monotonously increase within [0, 0.5] and monotonically decrease within [0.5, 1]. This constraint relationship can be expressed as:
According to the above description, a smoother curve can be obtained by optimizing the curvature to enhance the machining efficiency. Considering the constraints mentioned above, the optimization model can be given:
Objective function:
Constraint functions:
Design variables:
To solve the above problems, linear programming method is usually used to find the optimal solution. However, these optimal methods would consume much time. Therefore, this paper proposes a simple searching algorithm, which is given as follows.
Step 1: Initialize .
Step 2: Determine the control point by Equation (11) and obtain the curve Equation (3) with parameter .
Step 3: Set and .
Step 4: Calculate the curvature of the transition curve with Equation (27); if Equation (28) is satisfied, the curvature and the corresponding are stored and repeat step 3; if , go to step 5.
Step 5: Select corresponding to the minimum curvature.
2.3. Summary of the Proposed Method
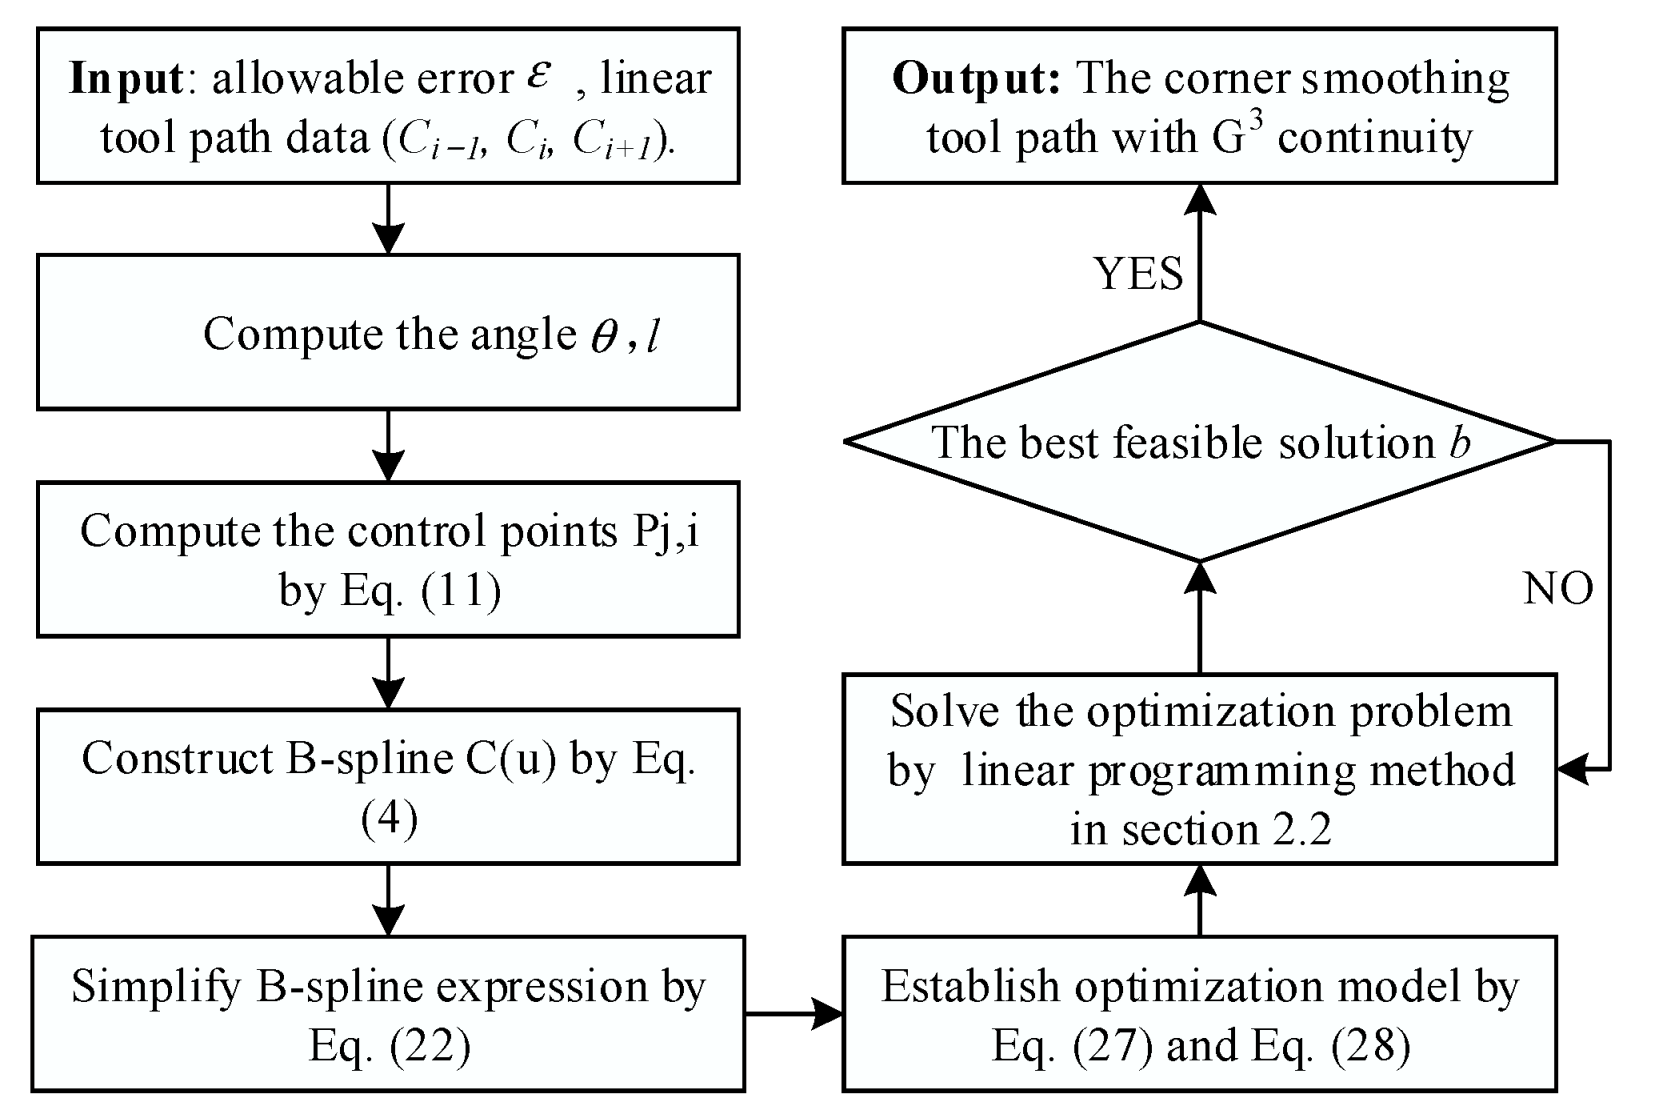
The flowchart of the proposed method can be summarized in Figure 2. Firstly, the error constraint and linear tool path are given. Then, the control points of the B-spline distributing inside and outside the straight line segment of the tool path (i.e., error feasible area) can be calculated with Equation (11). Then, the B-spline is constructed with Equation (4). To improve the smoothness of transition curve, the optimization model is established using Equations (27) and (28) and the optimization problem solved using the above linear programming method. Finally, the hybrid tool path with G3 continuity, including the transition curves and the linear segments, are obtained.
Figure 2.
Flowchart of the proposed method.
3. Simulation Experiment Verification
In this section, the proposed algorithm is verified by two examples and compared with Zhao’s [11] and Sun’s [26] methods. All programs were implemented with MATLAB 2014a on the PC with i7-8700cpu and 16 GB memory.
3.1. Example 1: The 2D Tool Path
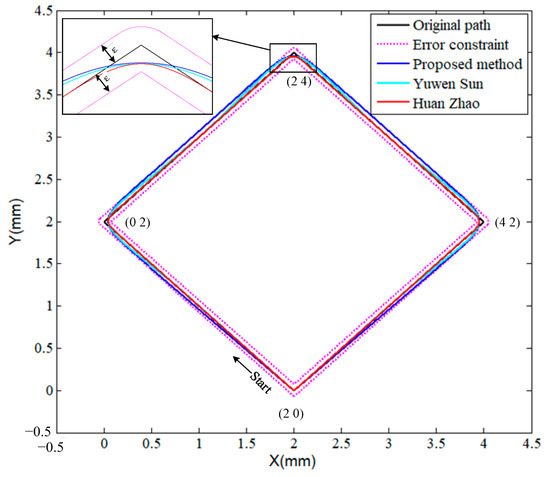
As seen in Figure 3, a rhombic tool path is smoothed by the three methods. The curves after transition are drawn with different colors. All methods used the same parameters. Specifically, the transition allowable error is 0.05 mm and the maximum velocity is 30 mm/s. The axis velocity, acceleration and jerk limits are 100 mm/s, 1000 mm/s2 and 120,000 mm/s3, respectively. From Table 1a, the maximal contour deviation obtained using three methods can satisfy the error constraint. To further compare the feasibility of the proposed method, some criteria (i.e., curvature, curvature derivative, machining time and kinematic fluctuation) were used to evaluate the quality of the smooth tool path.
Figure 3.
Corner-smoothing using three methods in rhombic tool path.
Table 1.
The comparison between three methods.
3.1.1. Curvature and Curvature Derivative
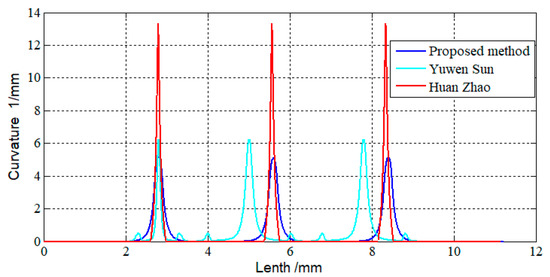
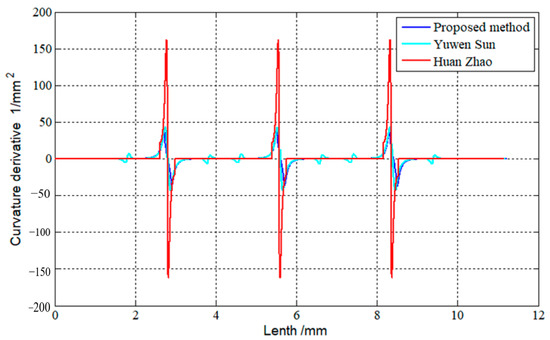
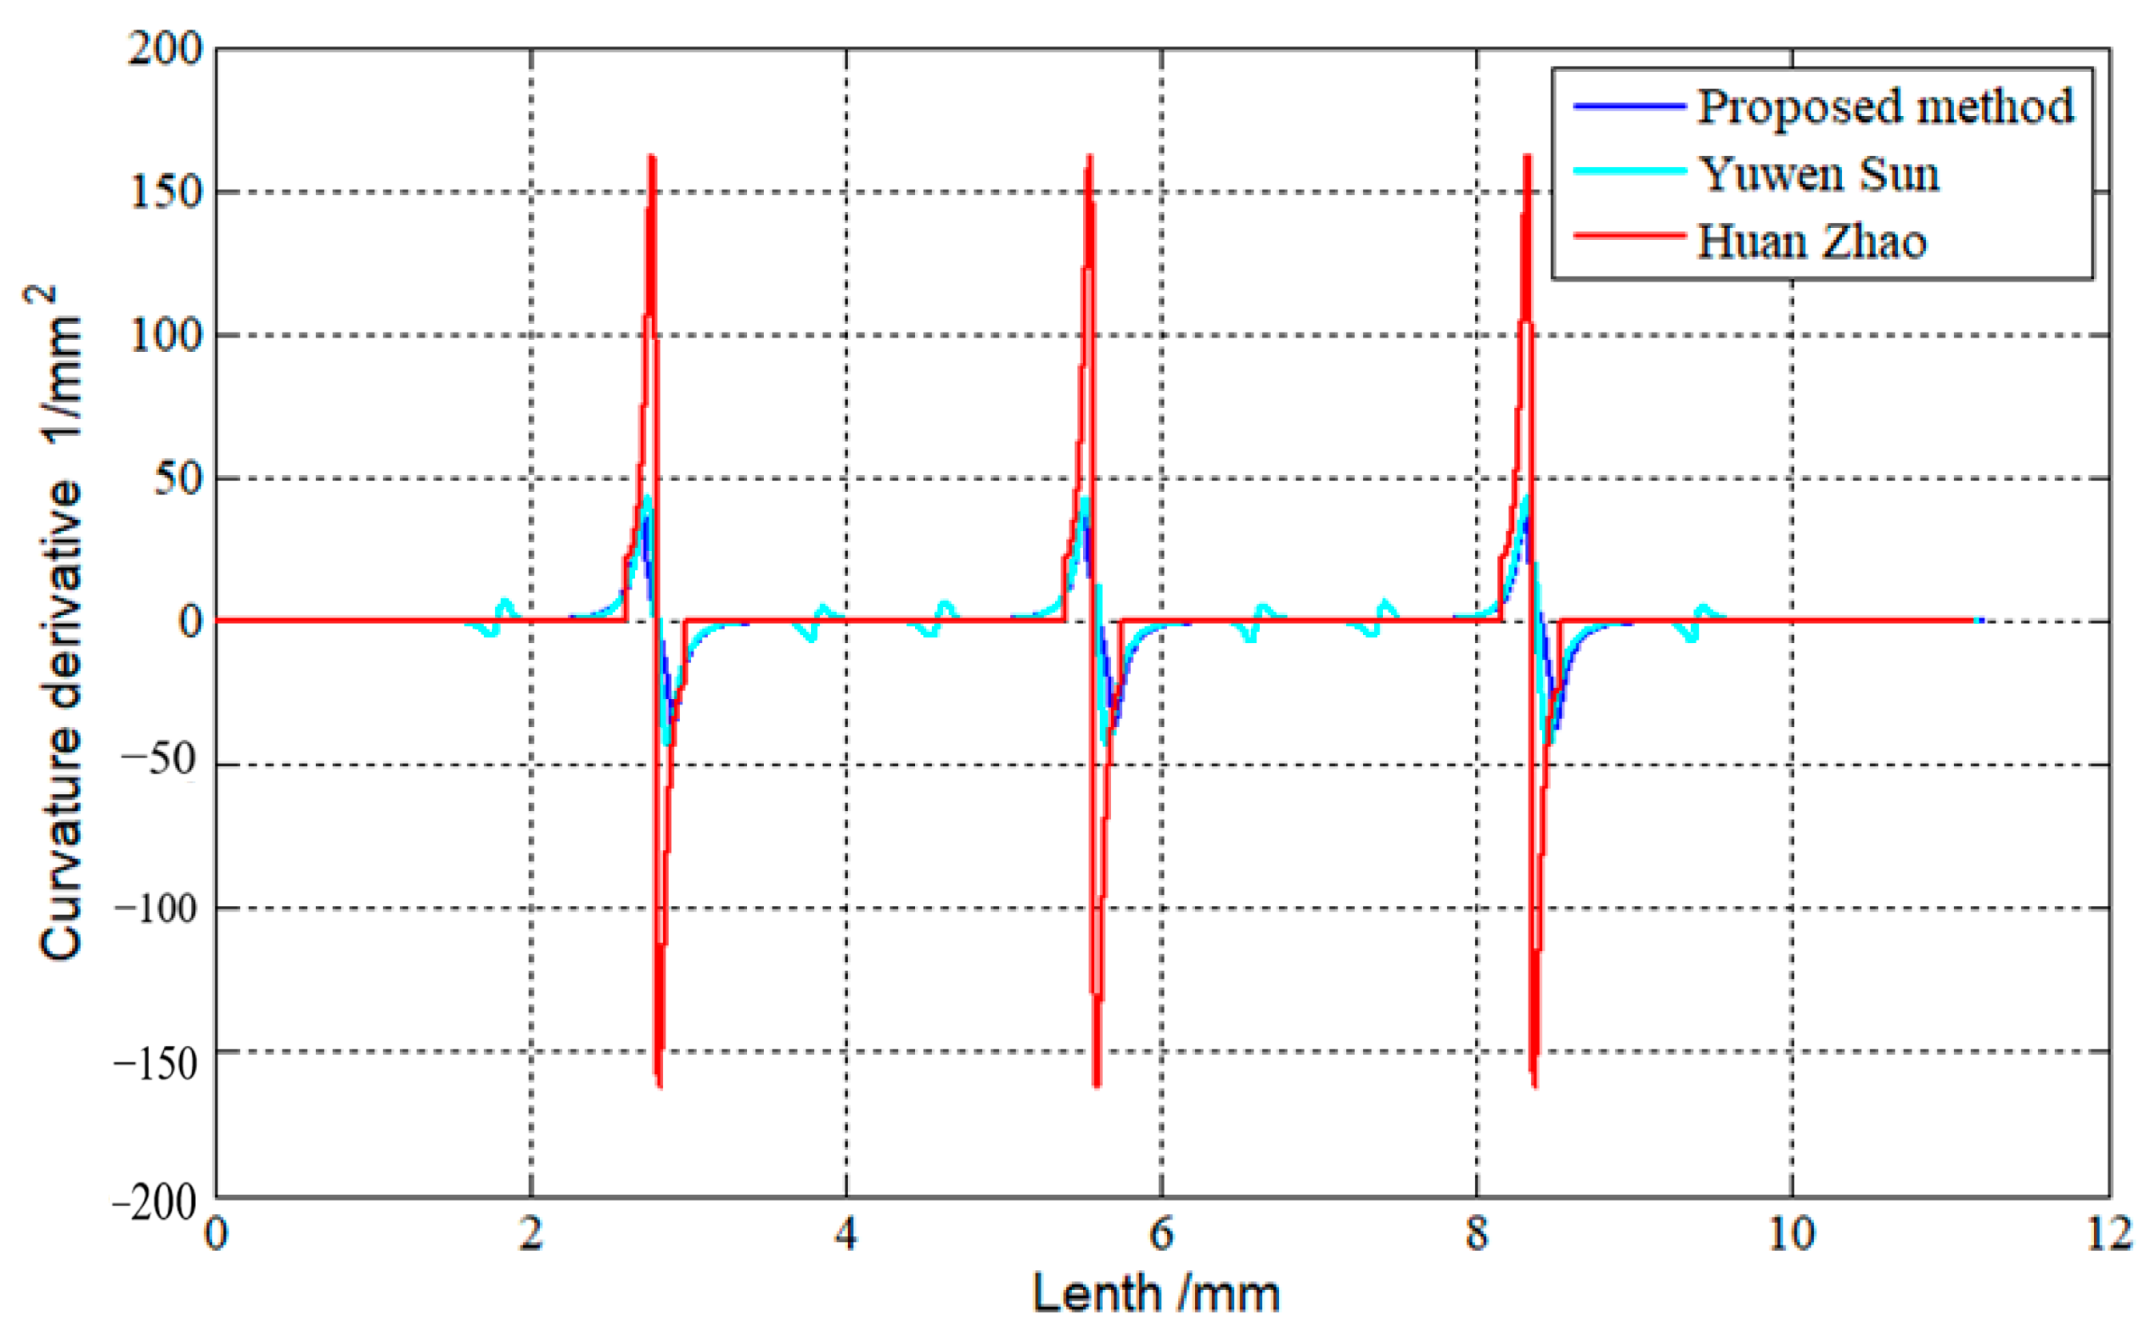
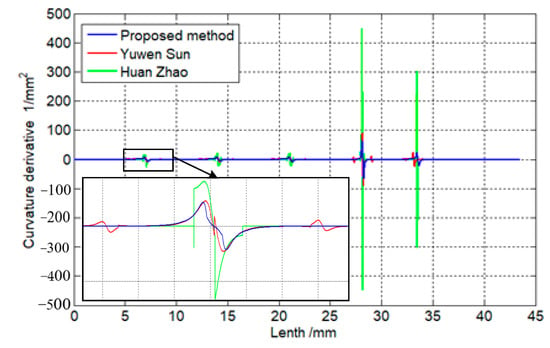
The speed and the machining efficiency can be improved by minimizing the curvature. The curvature and curvature derivative profiles are depicted in Figure 4 and Figure 5, respectively. Table 1a shows the maximal curvature and maximal curvature derivative of the tool paths generated by the three methods. As seen in Figure 4, the profiles of the curvatures obtained by the three methods are continuous, and the proposed method has a lower curvature value than the methods in Zhao’s [11] and Sun’s [26] works. Especially, in Table 1a, compared with Sun’s method and Zhao’s method, the maximal curvature extrema is reduced by about 19.6% and 161%, respectively. As shown in Figure 5, the profile of the curvature derivative obtained by Zhao’s method is discontinuous at the junction points and middle point of the corner transition curve, which would cause violent machining vibration. The curvature derivative profile of Sun et al. [26] changes frequently, resulting in more fluctuating profiles of the velocity. However, the curvature derivative profile obtained by the proposed method is continuous and the derivative value is also smaller than other methods, which can satisfy the requirements of G3 continuity and improve the smoothness of corner transition curves. From Table 1a, the G3 path proposed has lower curvature derivative extrema than the G2 path generated by the other two methods. The result demonstrates that the proposed method performs better in smoothness, which contributes to obtaining higher machining speed and machining stability.
Figure 4.
Curvature profiles of 2D tool path.
Figure 5.
Curvature derivative profiles of 2D tool path.
3.1.2. Machining Time and Kinematic Fluctuation
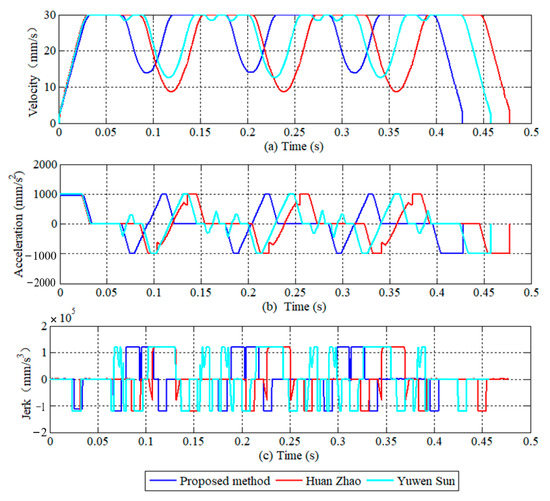
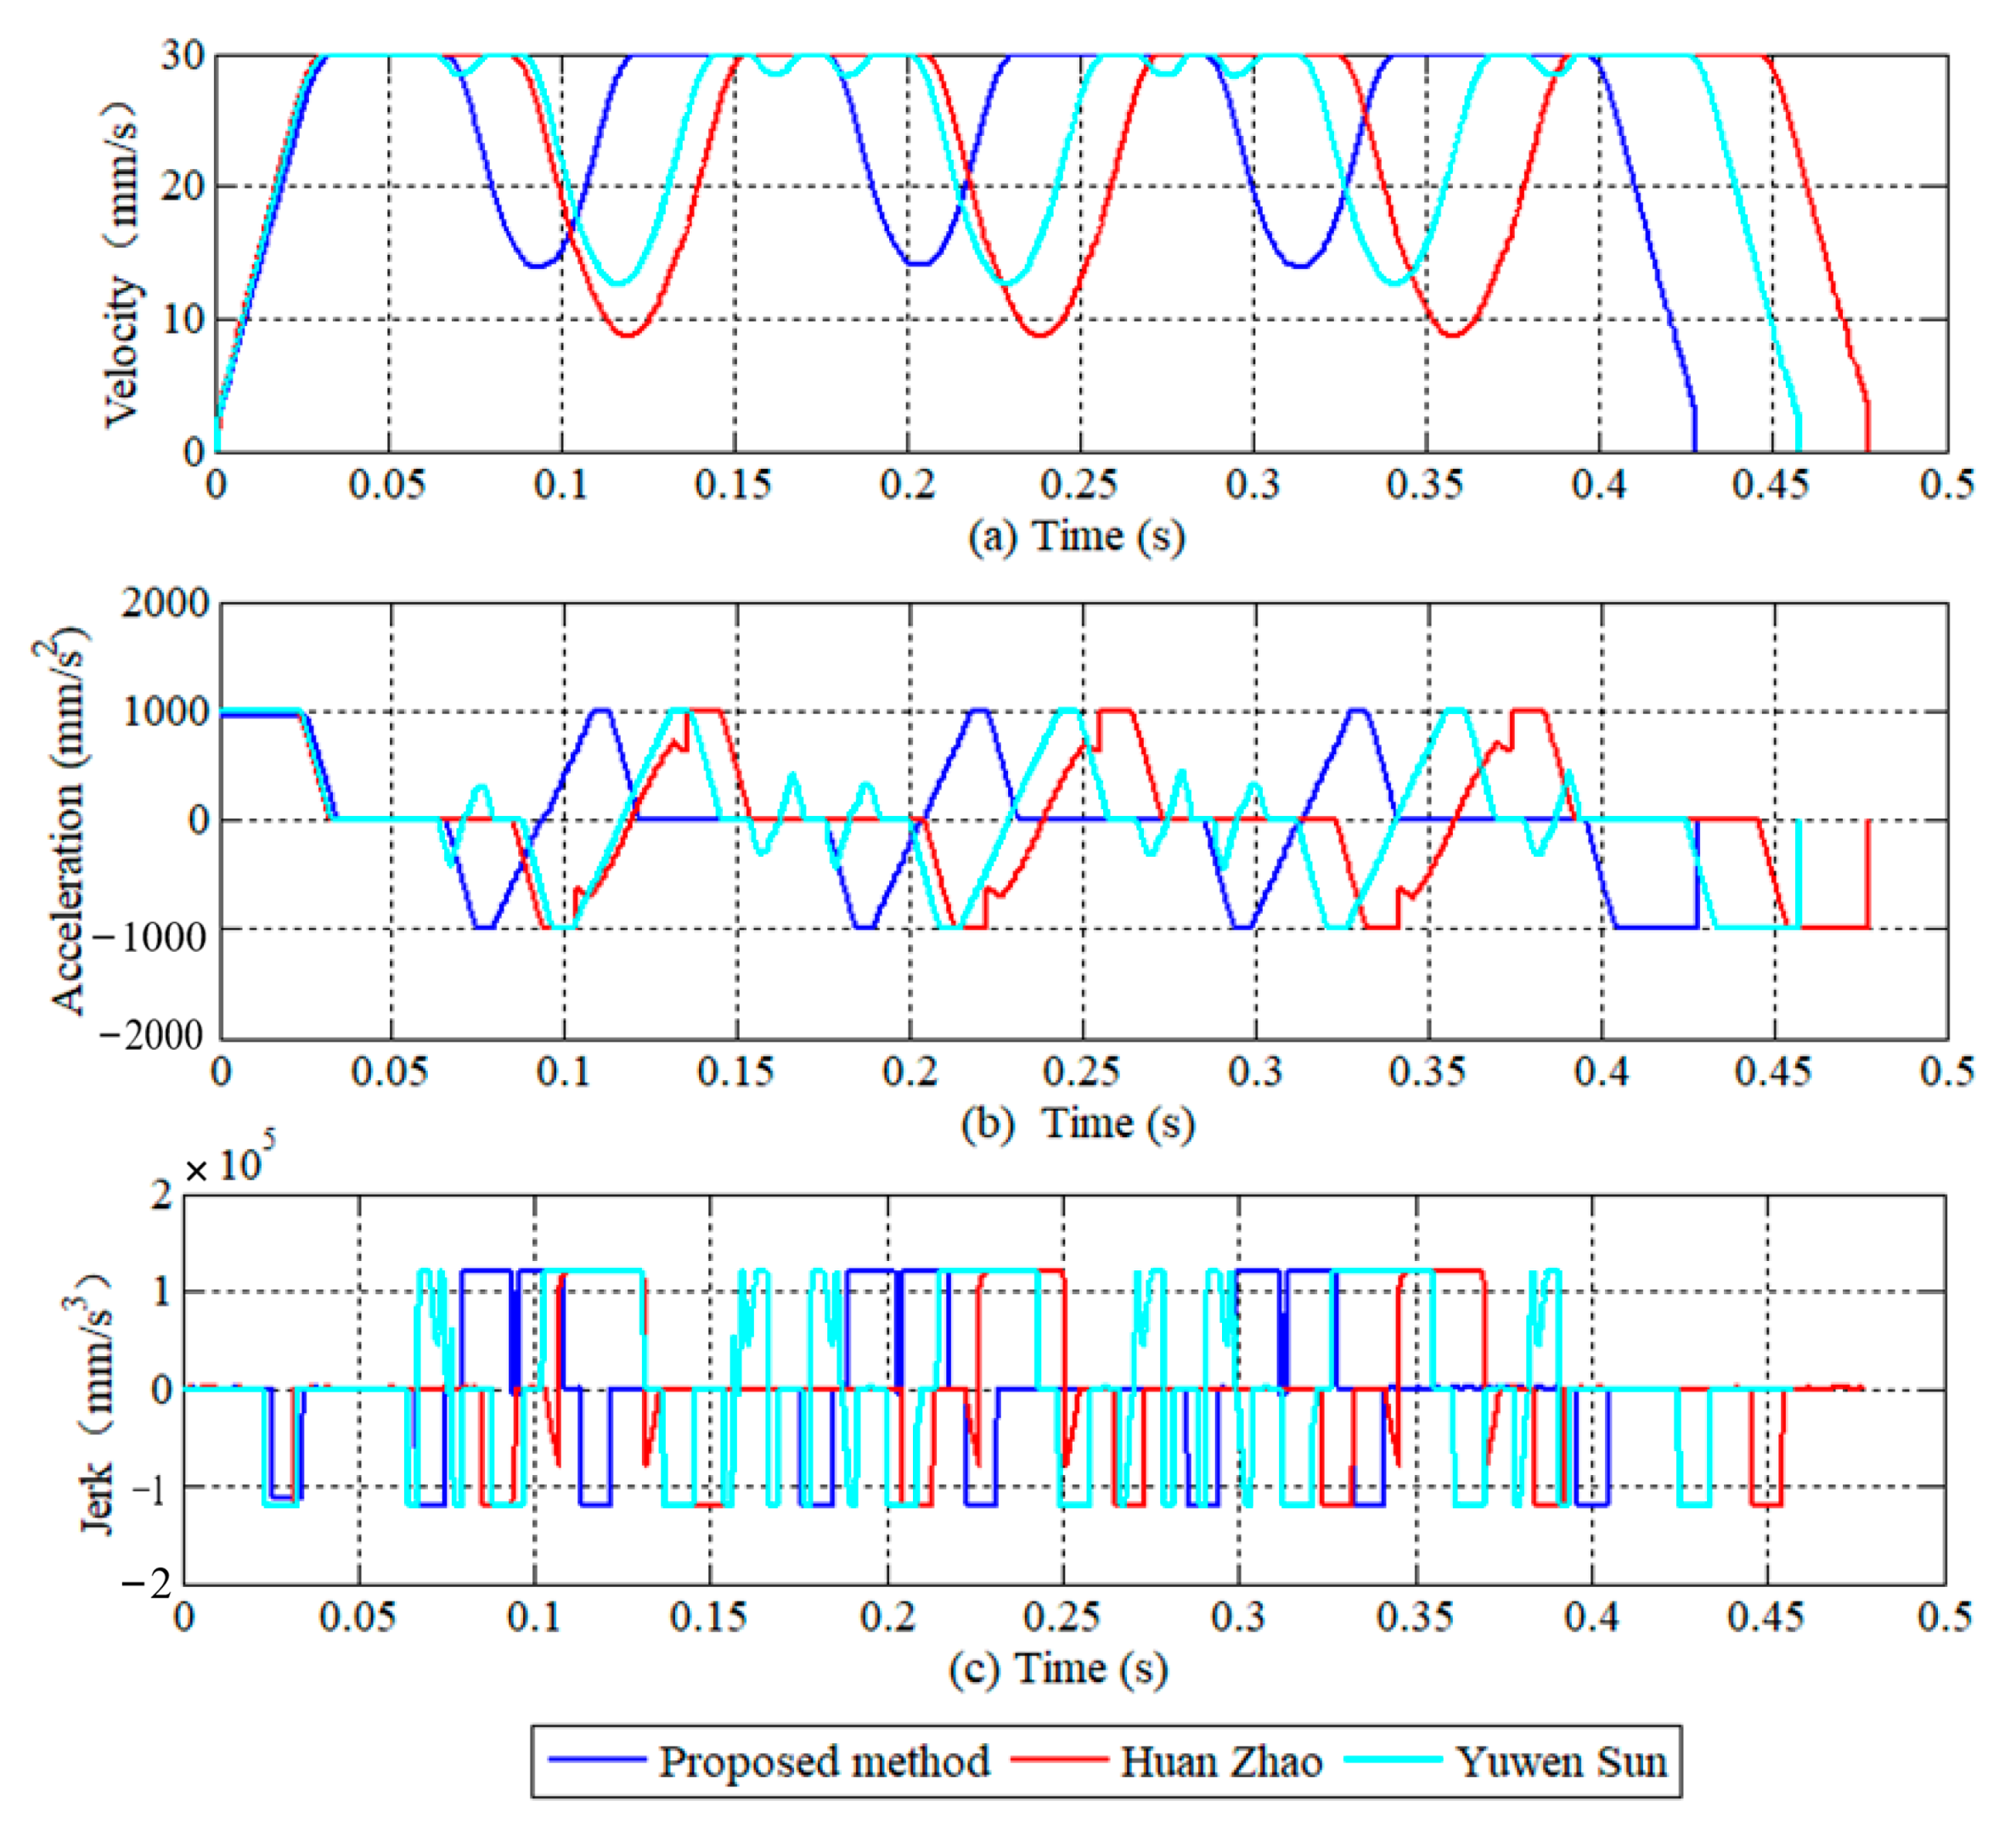
Machining time is a significant criterion of estimating machining efficiency. Low kinematic fluctuation can decrease machining vibration. As shown in Figure 6, kinematic profiles were calculated using the method developed by Zhao et al. [30]. From Table 1a, it can be seen that the proposed method improves the efficiency since the machining time is 11.7% and 6.8% shorter, respectively. In Figure 6a, the profile of this method also shows that the feedrate along the tool path has little fluctuation and the minimum speed increases significantly, but the fluctuation is obvious with the methods proposed by Zhao et al. [11] and Sun et al. [26]. As can be seen in Figure 6b,c, the acceleration and jerk of the novel corner smoothing method can respect the driving limits. Meanwhile, compared with other methods, the smoothness of acceleration is enhanced by applying the proposed corner smoothing method. Obviously, the example illustrates that the novel smoothing method can enhance the machining efficiency at the corners.
Figure 6.
The kinematic profiles (a) Velocity profiles. (b) Acceleration profiles. (c) Jerk profiles.
3.2. Example 2: The 3D Tool Path
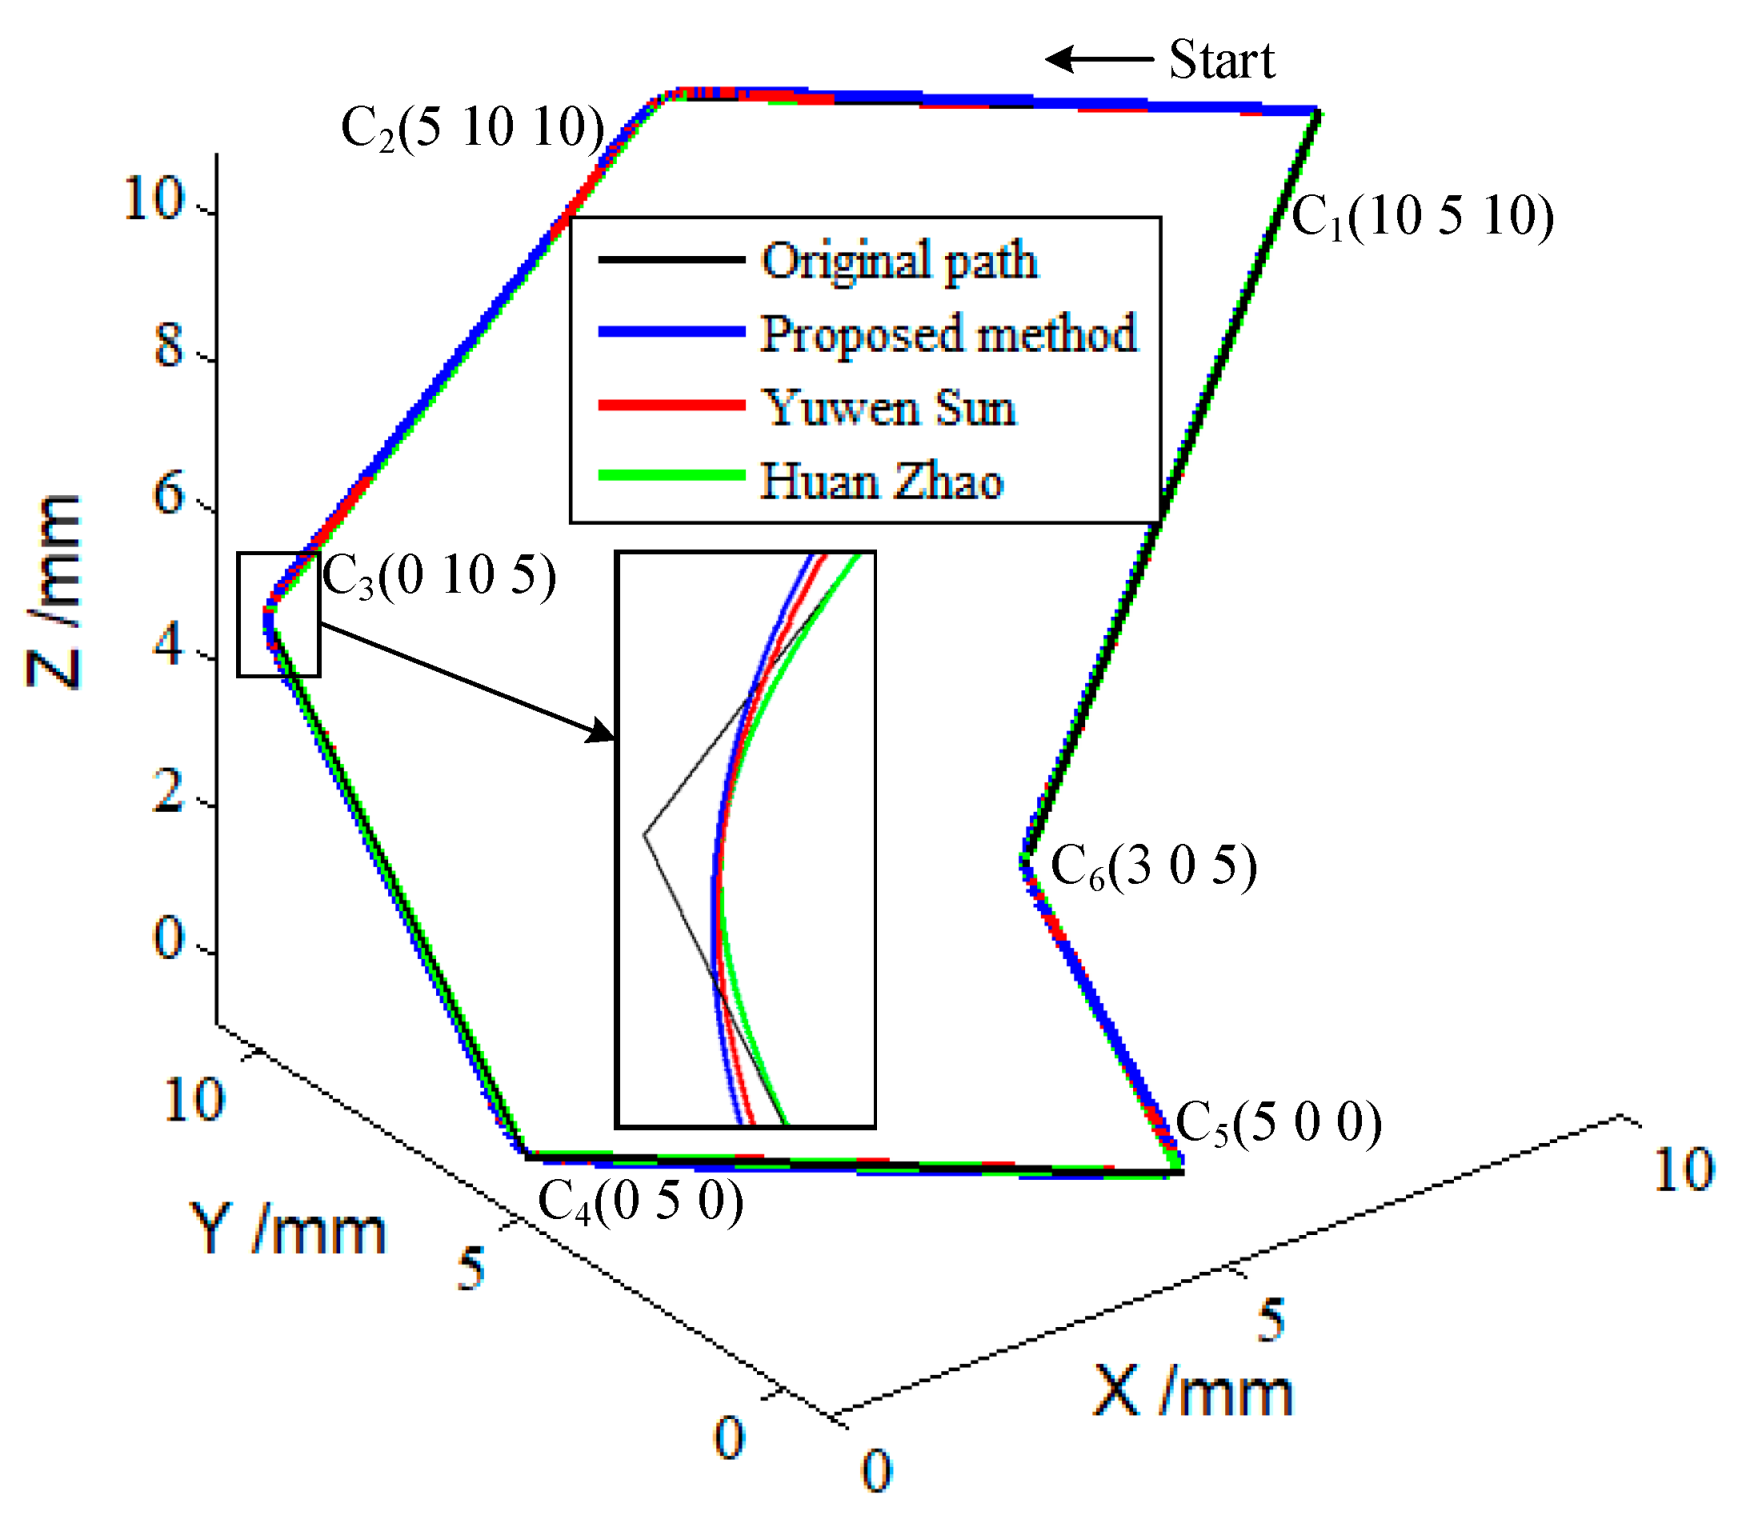
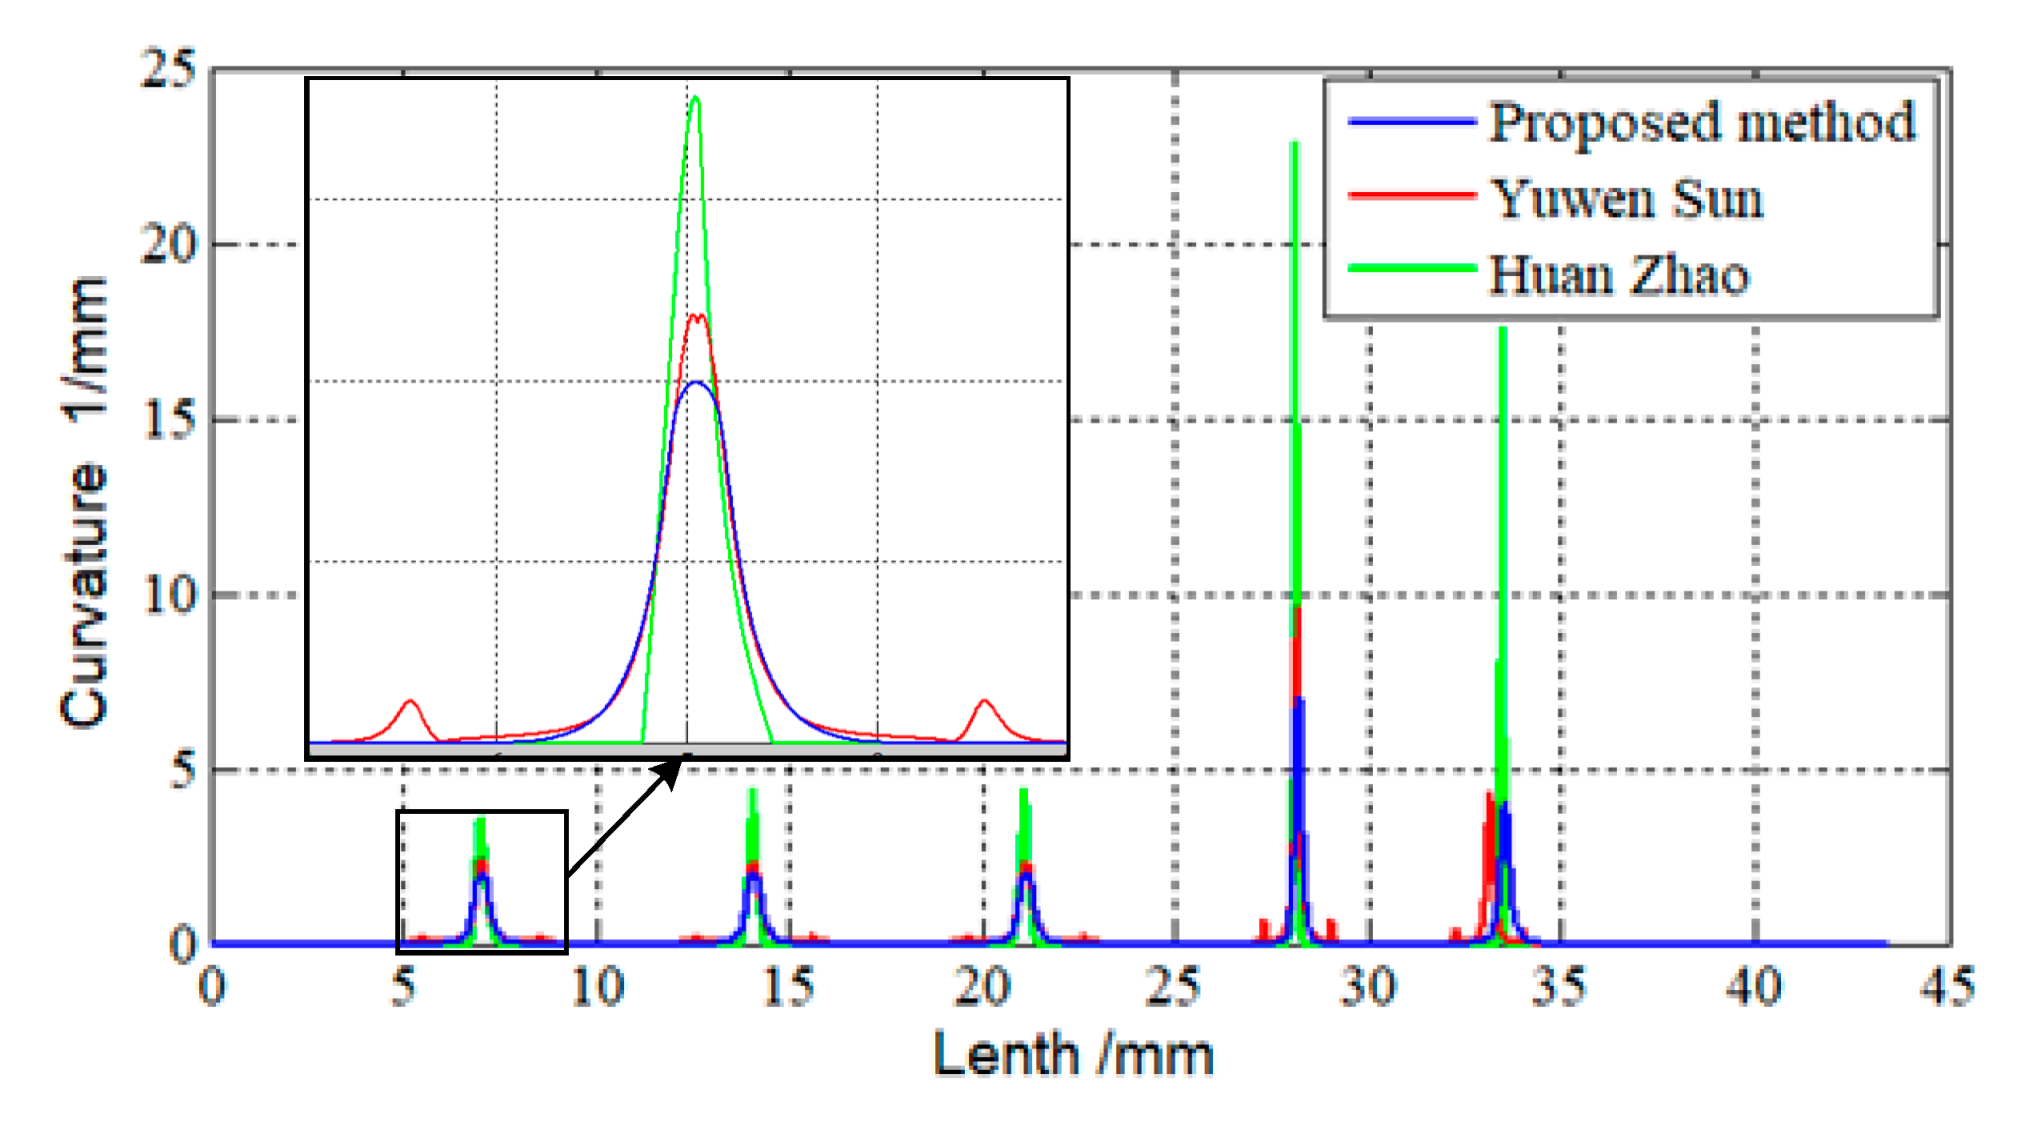
To further verify the feasibility of the novel corner smoothing method, a multi segment 3D linear tool path with different transition angles is shown in Figure 7. The parameters are the same as those in example 1. The transition curves obtained by the three methods are also drawn in Figure 7. The curvature and the curvature derivative with respect to the arc length are shown in Figure 8 and Figure 9. As illustrated in the two figures, the smoothing tool path generated by the proposed method has G3 continuity and there is only one curvature extrema in each transition curve. The curvature value is also smaller than that obtained by the other two methods from Table 1b, which proves the effectiveness of the proposed transition method. In addition, the simulation results show that the smooth performance of the transition curve is good. In addition, the simulation results show that the transition curves have satisfactory smoothness.
Figure 7.
The 3D tool path using three methods.
Figure 8.
Curvature profiles of 3D tool path.
Figure 9.
Curvature derivative profiles of 3D tool path.
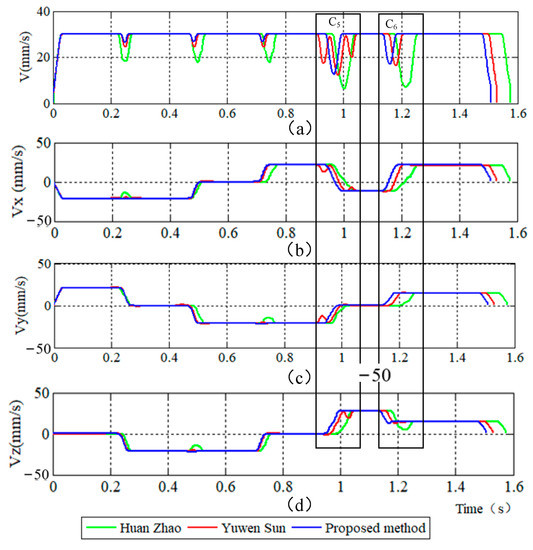
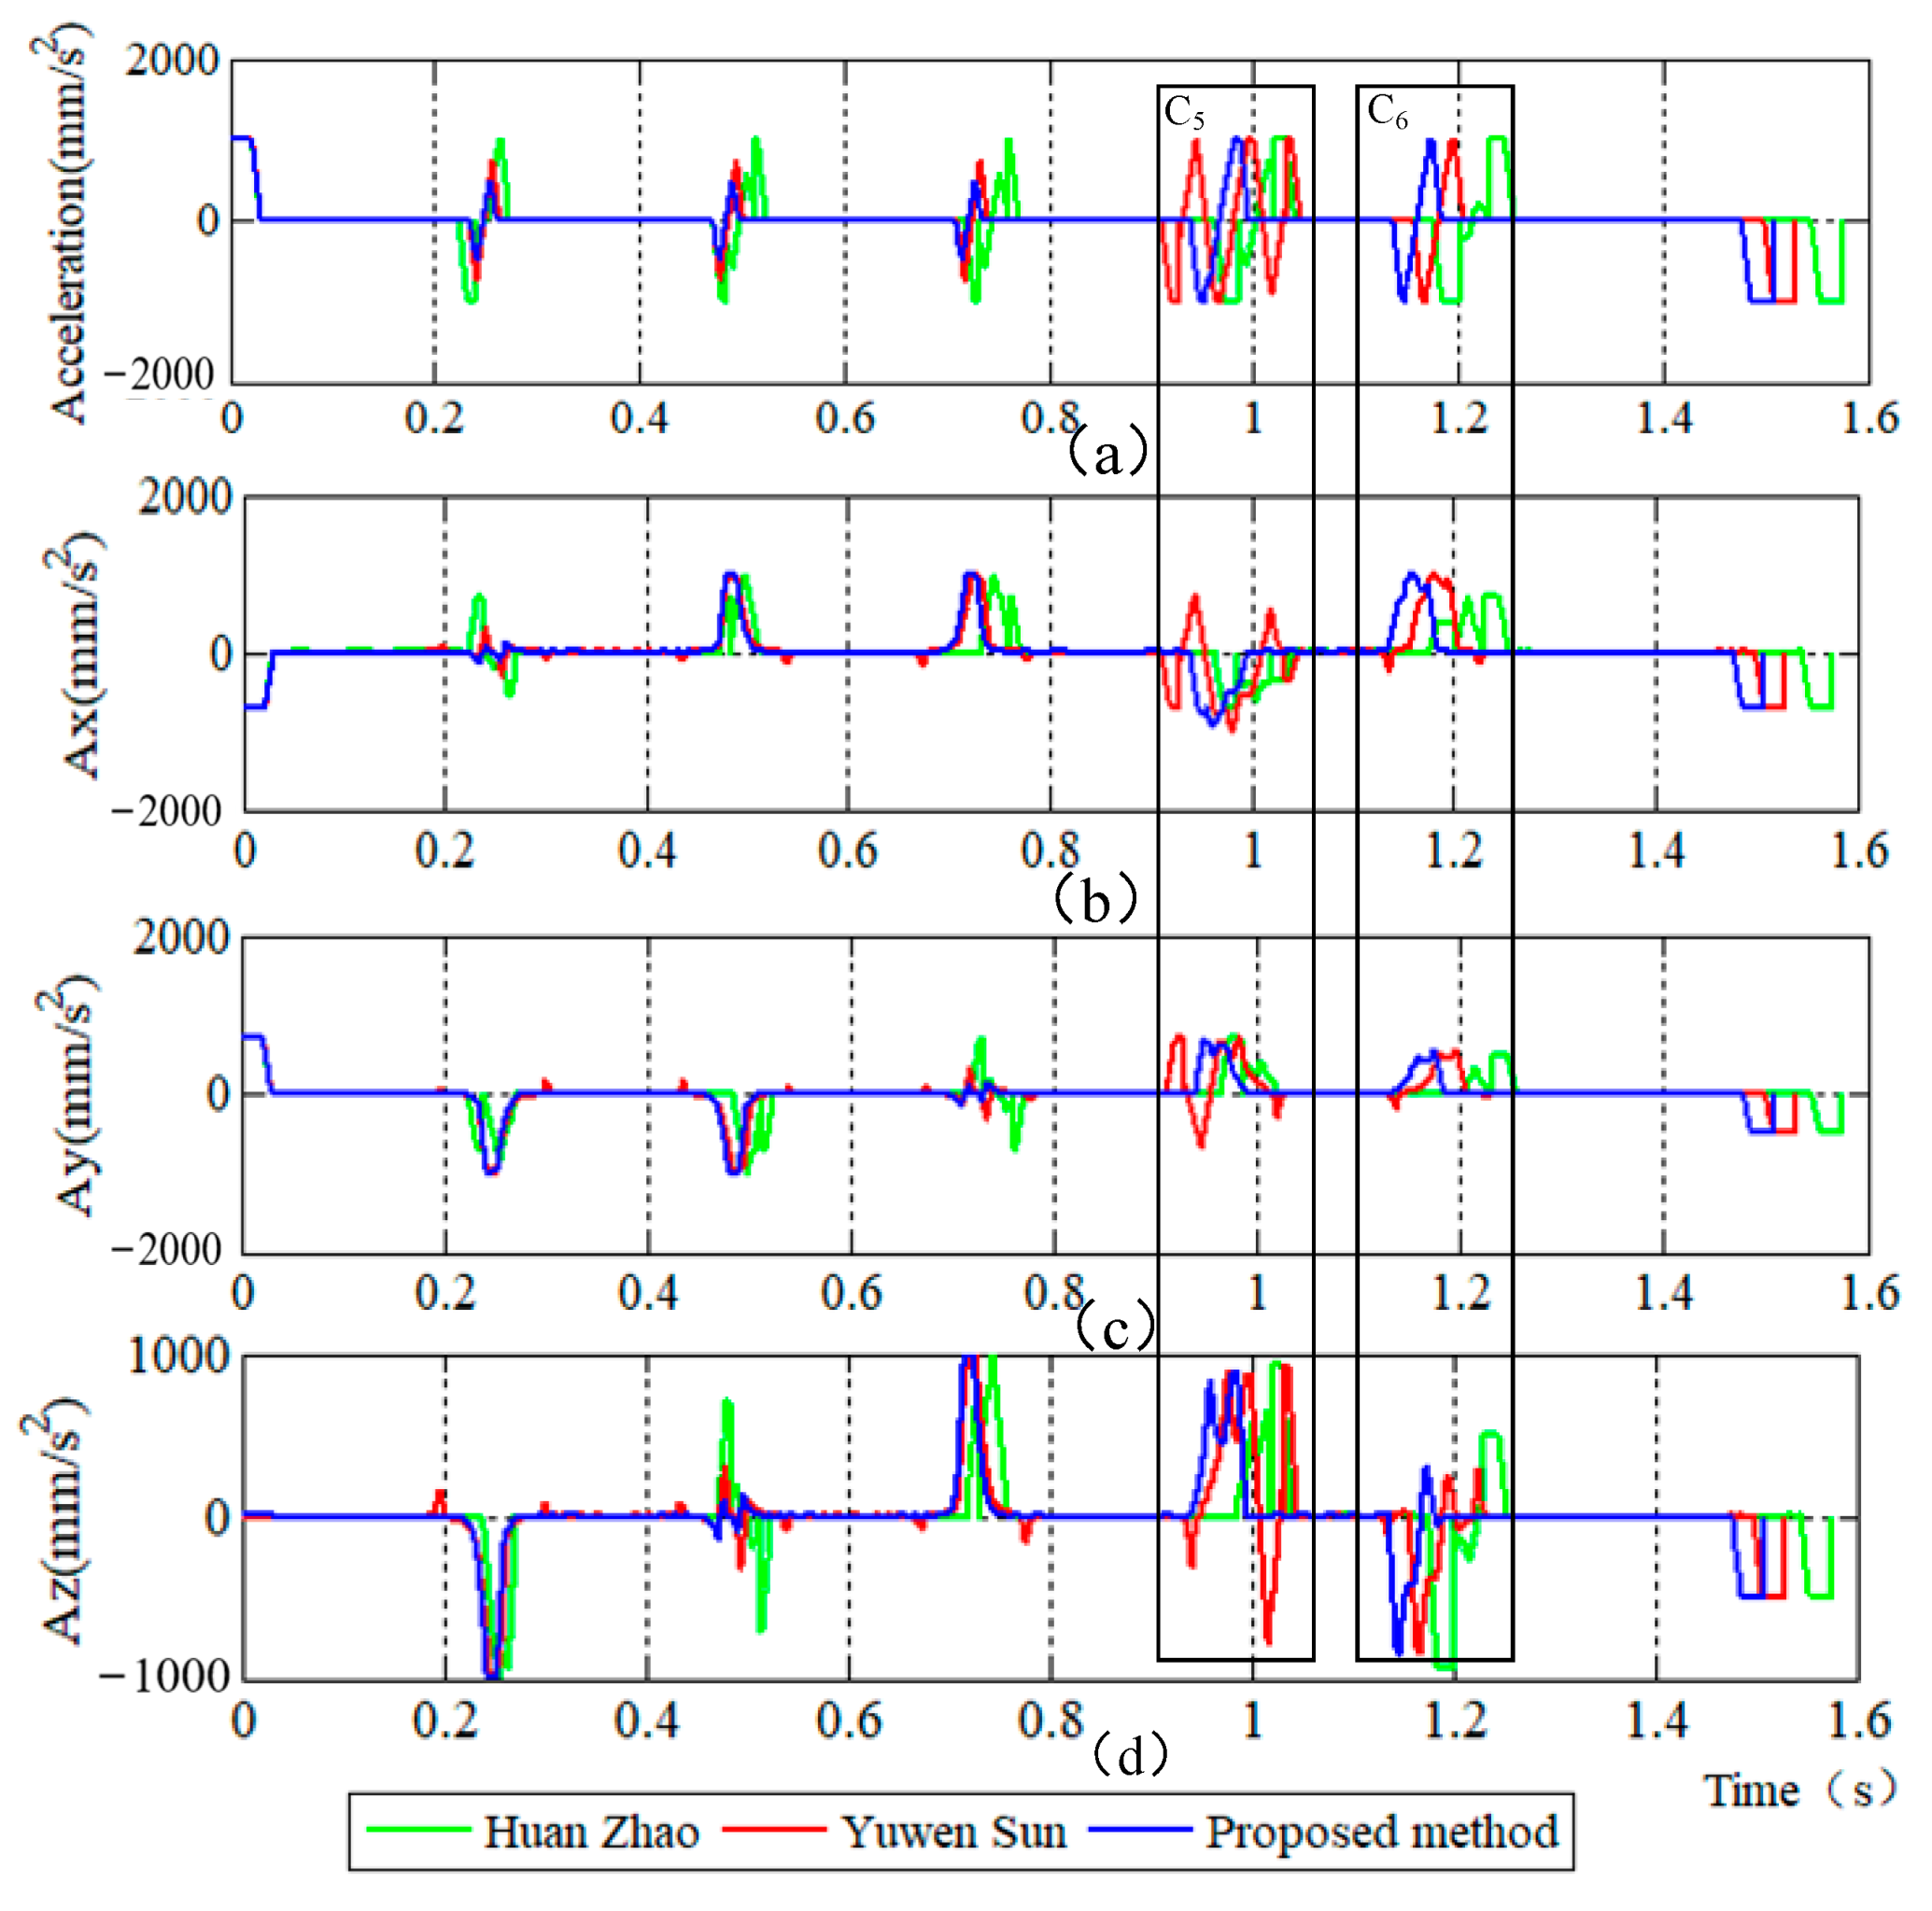
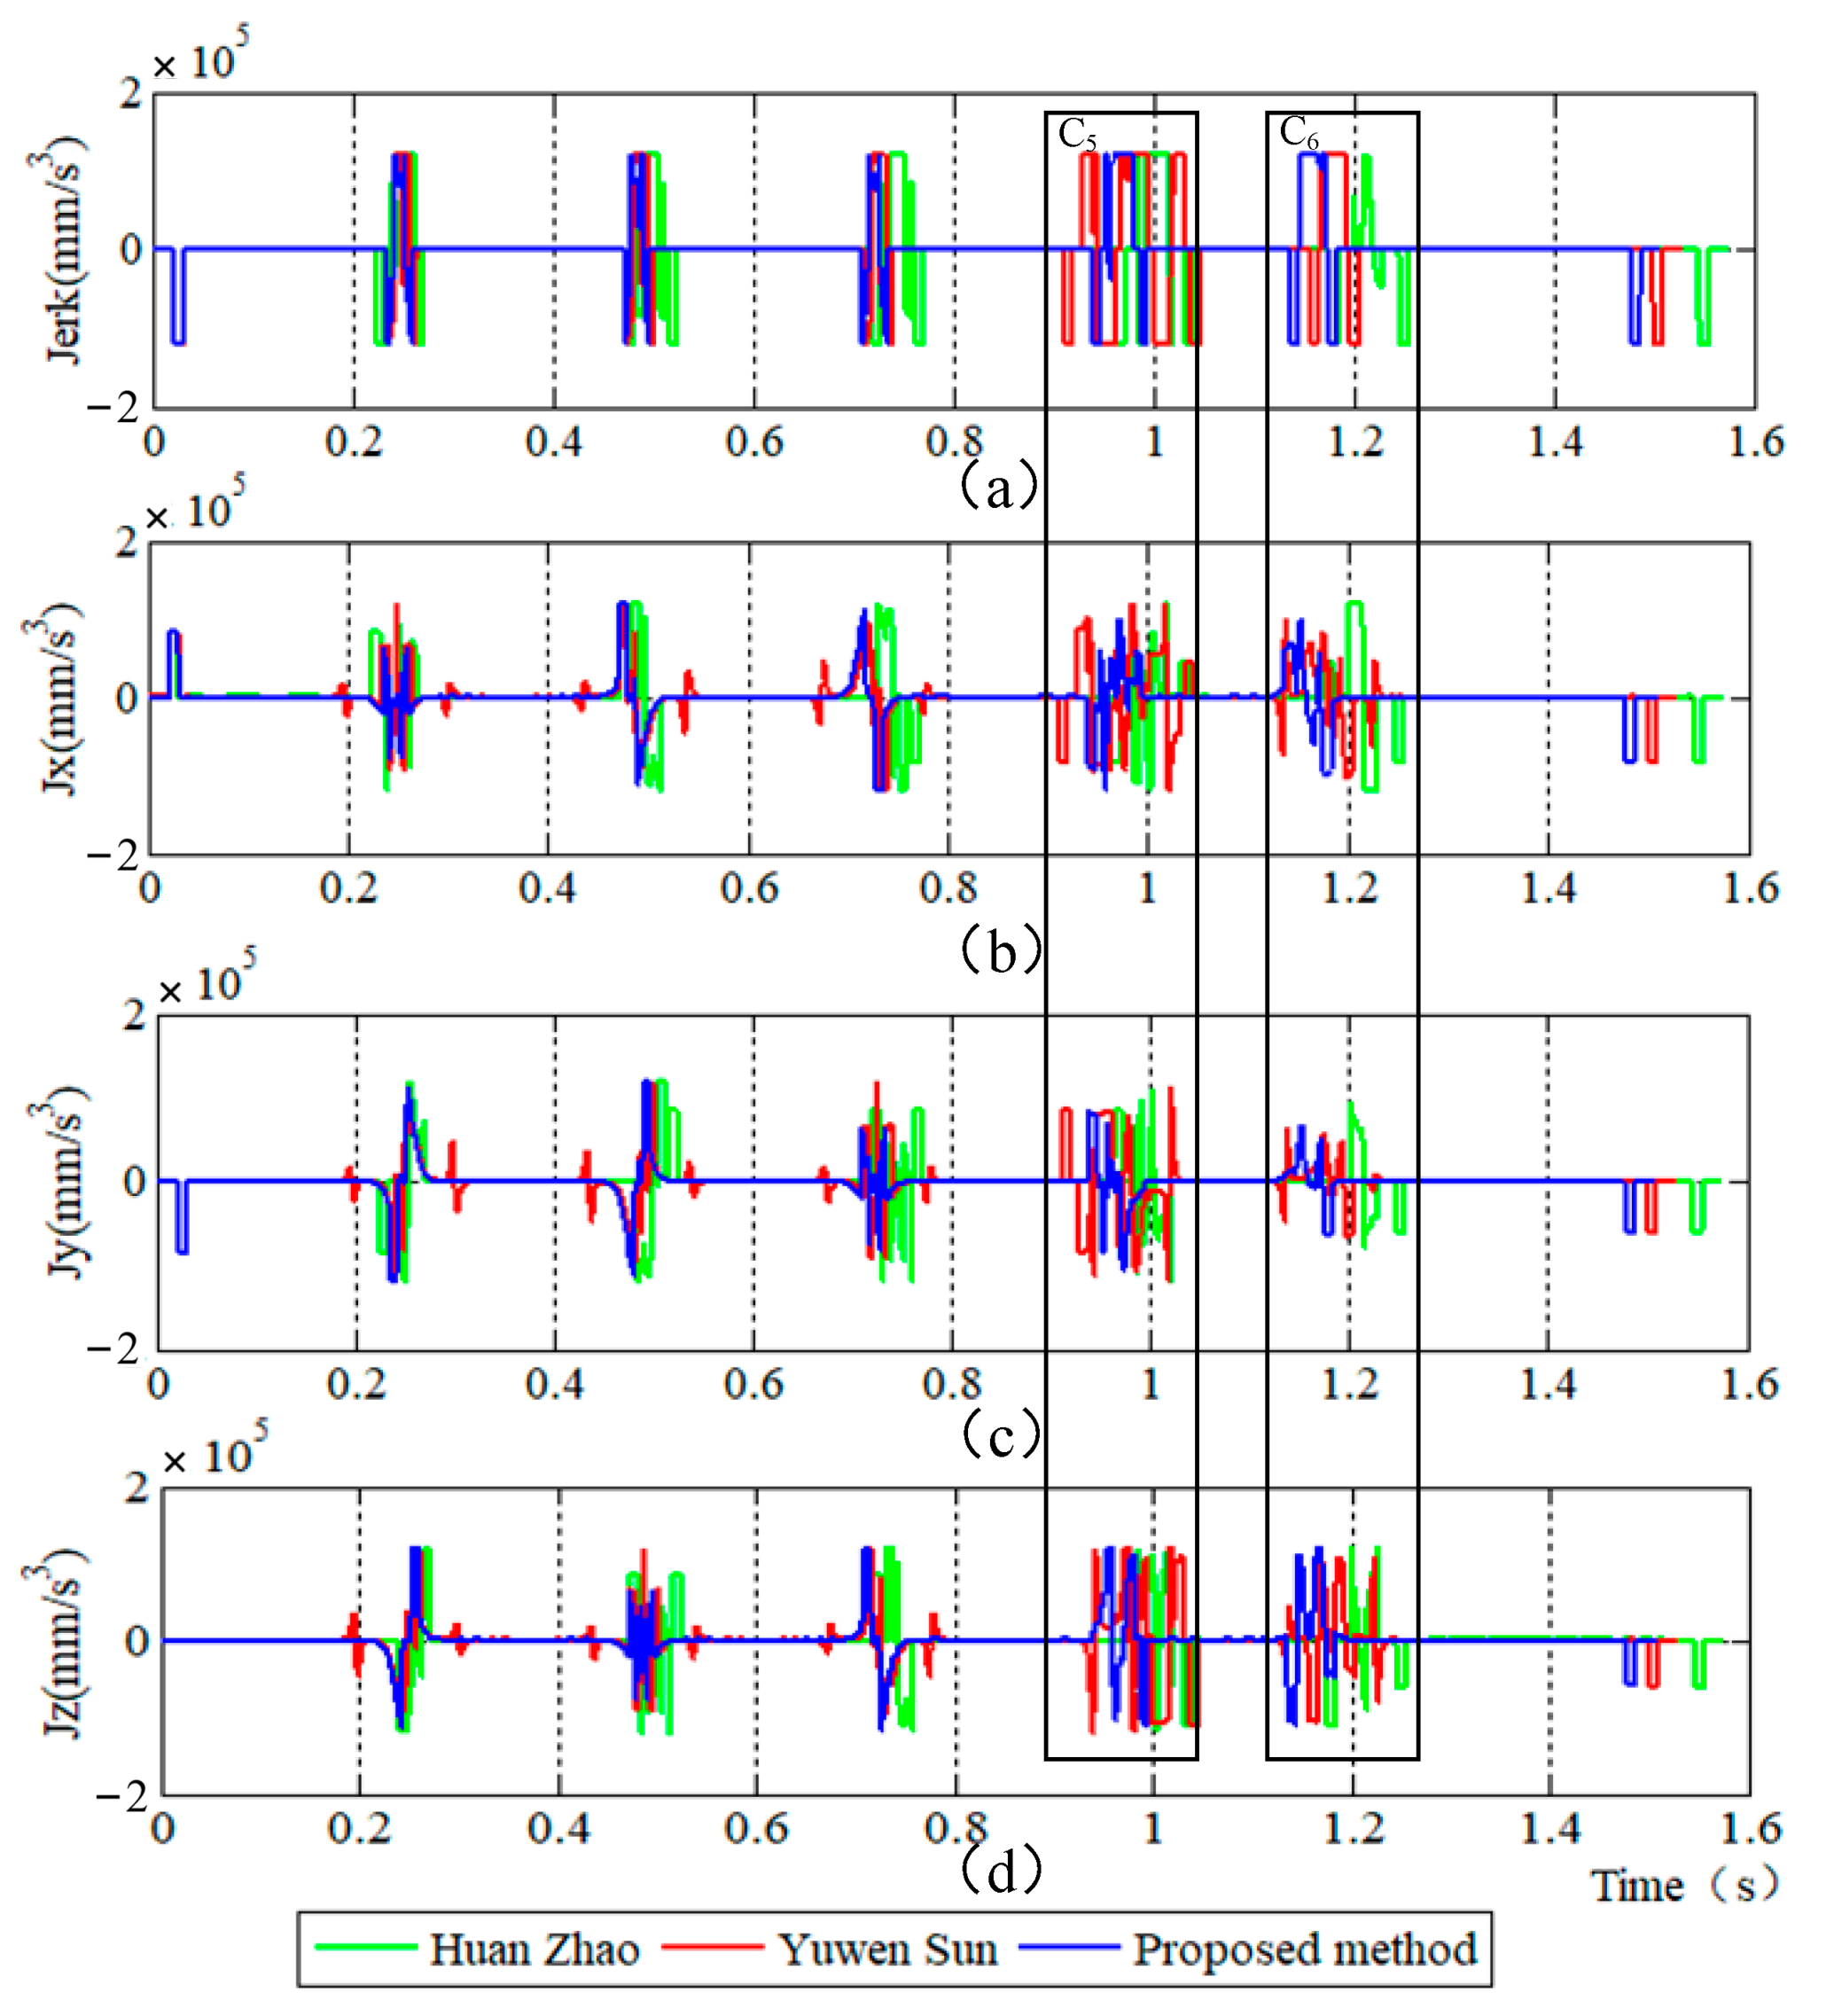
The profiles of the velocity are shown in Figure 10a. Since the transition curve is smoother, the proposed method can obtain the minimum machining time among the three methods, which can be seen in Table 1b. As observed in Figure 10b–d, the XYZ-axis velocity profiles become smoother. Figure 11a and Figure 12a show the acceleration and jerk profiles generated by the three methods. As shown, the limits of the acceleration and jerk for the drives are fully used and respect the given limits, but the corresponding profiles of the proposed method are smoother and the fluctuation is smaller. Especially in the corner and , compared with the frequent acceleration and deceleration processes occurring in the other two methods, the fluctuation in the acceleration and jerk profiles generated by the proposed method is significantly reduced. In addition, it is well-known that the profiles of axial acceleration and jerk would affect the vibration behavior of the machining process [31]. In the Figure 11b–d and Figure 12b–d, the XYZ-axis acceleration and jerk profiles of the proposed method are smoother with less fluctuation, which can reduce the machining vibration. In this case, our optimal method may achieve better contour performance and surface quality.
Figure 10.
Velocity profiles of 3D tool path.
Figure 11.
Acceleration profiles of 3D tool path.
Figure 12.
Jerk profiles of 3D tool path.
4. Conclusions
A geometrically smooth tool path plays an important part in realizing high-speed and high-precision NC machining. Thus, a novel corner-smoothing transition method is proposed in this paper. Compared with the previous literatures using higher-order curves with all control points lying in a straight segment and inside of the tool path, the proposed method is based on the error feasible area and reasonably selects the curve control point. Moreover, the curvature of the B-spline transition curves is optimized to enhance the smoothness and keep the G3 continuity of the mixed tool path, which has smaller curvature and higher feed speed at the sharp corners between the linear tool paths. According to the above advantages, the kinematic profiles of the machining process are relatively smooth with less fluctuation and the machining stability is improved, which can increase machining efficiency and surface quality. Finally, the feasibility and effectiveness of the proposed method were validated by simulations and compared with other already existing methods.
Author Contributions
X.Y. wrote the paper and supervised the work; Y.Y. gave some suggestions on the simulations. All authors have read and agreed to the published version of the manuscript.
Funding
This study was funded partially by the National Science Foundation of China (51775279) and National Key Research and Development Plan of China (2018YFB1309203).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Data sharing is not applicable to this article.
Conflicts of Interest
The authors declare that there is no conflict of interest.
Appendix A
References
- Ferry, W.B.; Altintas, Y. Virtual five-axis flank milling of jet engine impellers part I: Mechanics of five-axis flank milling. J. Manuf. Sci. Eng. 2008, 130, 11005. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Ye, P.; Zhang, H.; Zhao, M. A Local and Analytical Curvature-Smooth Method with Jerk-Continuous Feedrate Scheduling along Linear Toolpath. Int. J. Precis. Eng. Manuf. 2018, 19, 1529–1538. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Zhao, M.; Ye, P.; Zhang, H. A G4 continuous B-spline transition algorithm for cnc machining with jerk-smooth feedrate scheduling along linear segments. Comput.-Aided Des. 2019, 115, 231–243. [Google Scholar] [CrossRef] [Scilit]
- Wu, K.; Krewet, C.; Kuhlenkötter, B. Dynamic performance of industrial robot in corner path with CNC controller. Robot. Comput.-Integr. Manuf. 2018, 54, 156–161. [Google Scholar] [CrossRef] [Scilit]
- Pessoles, X.; Landon, Y.; Rubio, W. Kinematic modelling of a 3-axis NC machine tool in linear and circular interpolation. Int. J. Adv. Manuf. Technol. 2010, 47, 639–655. [Google Scholar] [CrossRef] [Scilit]
- Yang, K.M.; Shi, C.; Ye, P.Q.; Lv, Q. Smooth transfer control algorithm for continuous segment trajectory in computer numerical control systems. J. Tsinghua Univ. (Sci. Technol.) 2007, 47, 1295–1299. [Google Scholar]
- Bi, Q.; Wang, Y.; Zhu, L.; Ding, H. A practical continuous curvature Bezier transition algorithm for high-speed machining of linear tool path. In Intelligent Robotics and Applications, Proceedings of the 4th International Conference, (ICIRA 2011), Aachen, Germany, 6–8 December 2011; Jeschke, S., Liu, H., Schilberg, D., Eds.; Springer: Berlin/Heidelberg, Germany, 2011; pp. 465–476. [Google Scholar]
- Xu, D.; Jie, H.; Li-Min, Z. A locally optimal transition method with analytical calculation of transition length for computer numerical control machining of short line segments. Proc. Inst. Mech. Eng. 2018, 232, 2409–2419. [Google Scholar]
- Pateloup, V.; Duc, E.; Ray, P. B-spline approximation of circle arc and straight line for pocket machining. Comput.-Aided Des. 2010, 42, 817–827. [Google Scholar] [CrossRef] [Scilit]
- Zhang, L.B.; You, Y.P.; He, J.; Yang, X.F. The transition algorithm based on parametric spline curve for high-speed machining of continuous short line segments. Int. J. Adv. Manuf. Technol. 2011, 52, 245–254. [Google Scholar] [CrossRef] [Scilit]
- Zhao, H.; Zhu, L.M.; Ding, H. A real-time look-ahead interpolation methodology with curvature-continuous b-spline transition scheme for cnc machining of short line segments. Int. J. Mach. Tools Manuf. 2013, 65, 88–98. [Google Scholar] [CrossRef] [Scilit]
- Han, J.; Jiang, Y.; Tian, X.; Chen, F.; Lu, C.; Xia, L. A local smoothing interpolation method for short line segments to realize continuous motion of tool axis acceleration. Int. J. Adv. Manuf. Technol. 2018, 95, 1729–1742. [Google Scholar] [CrossRef] [Scilit]
- Sencer, B.; Ishizaki, K.; Shamoto, E. A curvature optimal sharp corner smoothing algorithm for high-speed feed motion generation of NC systems along linear tool paths. Int. J. Adv. Manuf. Technol. 2015, 76, 1977–1992. [Google Scholar] [CrossRef] [Scilit]
- Farouki, R.T. Construction of G2 rounded corners with Pythagorean-hodograph curves. Comput. Aided Geom. Des. 2014, 31, 127–139. [Google Scholar] [CrossRef] [Scilit]
- Shi, J.; Bi, Q.Z.; Wang, Y.H.; Liu, G. Development of real-time look-ahead methodology based on quintic PH curve with G2 continuity for high-speed machining. Appl. Mech. Mater. 2014, 464, 258–264. [Google Scholar] [CrossRef] [Scilit]
- Huang, X.; Zhao, F.; Tao, T.; Mei, X. A newly developed corner smoothing methodology based on clothoid splines for high speed machine tools. Robot. Comput.-Integr. Manuf. 2021, 70, 102106. [Google Scholar] [CrossRef] [Scilit]
- Fan, W.; Lee, C.H.; Chen, J.H. A realtime curvature-smooth interpolation scheme and motion planning for CNC machining of short line segments. Int. J. Mach. Tools Manuf. 2015, 96, 27–46. [Google Scholar] [CrossRef] [Scilit]
- Yang, X.; You, Y.; Yang, W.A. Simultaneous optimization of curvature and curvature variation for tool path generation in high-speed milling of corners. J. Braz. Soc. Mech. Sci. Eng. 2022, 44, 68. [Google Scholar] [CrossRef] [Scilit]
- Tulsyan, S.; Altintas, Y. Local toolpath smoothing for five-axis machine tools. Int. J. Mach. Tools Manuf. 2015, 96, 15–26. [Google Scholar] [CrossRef] [Scilit]
- Zhang, Y.; Mingyong, Z.; Peiqing, Y.; Jiang, J.; Zhang, H. Optimal curvature-smooth transition and efficient feedrate optimization method with axis kinematic limitations for linear toolpath. Int. J. Adv. Manuf. Technol. 2018, 99, 169–179. [Google Scholar] [CrossRef] [Scilit]
- Du, X.; Wang, B. A C3-continuous NURBS transition scheme for the CNC machining of short linear segments. Precis. Eng. 2022, 73, 1–10. [Google Scholar] [CrossRef] [Scilit]
- Hu, Q.; Chen, Y.; Yang, J.; Zhang, D. An analytical C3 continuous local corner smoothing algorithm for four-axis computer numerical control machine tools. J. Manuf. Sci. Eng. 2018, 140, 051004. [Google Scholar] [CrossRef] [Scilit]
- Hu, Q.; Chen, Y.; Jin, X.; Yang, J. A real-time C3 continuous tool path smoothing and interpolation algorithm for five-axis machine tools. J. Manuf. Sci. Eng. 2020, 142, 041002. [Google Scholar] [CrossRef] [Scilit]
- Sun, S.; Altintas, Y. A G3 continuous tool path smoothing method for 5-axis CNC machining. CIRP J. Manuf. Sci. Technol. 2021, 32, 529–549. [Google Scholar] [CrossRef] [Scilit]
- Sun, S. A G3 continuous five-axis tool path corner smoothing method with improved machining efficiency and accurately controlled deviation of tool axis orientation. Int. J. Adv. Manuf. Technol. 2022, 119, 7003–7024. [Google Scholar] [CrossRef] [Scilit]
- Xu, F.; Sun, Y. A circumscribed corner rounding method based on double cubic B-splines for a five-axis linear tool path. Int. J. Adv. Manuf. Technol. 2018, 94, 451–462. [Google Scholar] [CrossRef] [Scilit]
- Moore, P.; Molloy, D. Efficient Energy Evaluations for Active B-Spline/NURBS Surfaces. Comput.-Aided Des. 2014, 47, 12–31. [Google Scholar] [CrossRef] [Scilit]
- Lee, A.C.; Lin, M.T.; Pan, Y.R.; Lin, W.Y. The feedrate scheduling of nurbs interpolator for CNC machine tools. Comput.-Aided Des. 2011, 43, 612–628. [Google Scholar] [CrossRef] [Scilit]
- Lai, J.Y.; Lin, K.Y.; Tseng, S.J.; Ueng, W.D. On the development of a parametric interpolator with confined chord error, feedrate, acceleration and jerk. Int. J. Adv. Manuf. Technol. 2008, 37, 104–121. [Google Scholar] [CrossRef] [Scilit]
- Zhao, X.; Zhao, H.; Yang, J.; Ding, H. An adaptive feedrate scheduling method with multi-constraints for five-axis machine tools. In Proceedings of the International Conference on Intelligent Robotics and Applications 2015, Portsmouth, UK, 24 August 2015; Springer: Cham, Switzerland, 2015; pp. 553–564. [Google Scholar]
- Barre, P.; Bearee, R.; Borne, P.; Dumetz, E. Influence of a jerk controlled movement law on the vibratory behaviour of highdynamics systems. J. Intell. Robot. Syst. 2005, 42, 275–293. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).