


Abstract
An enhanced interpolation approach is developed for simulating nonseparable nonstationary ground motions on the basis of the spectral representation method, which mainly contains two steps of interpolations and an optimization. Firstly, the interpolation technique is utilized to reduce the Cholesky decomposition time of the lagged coherence matrix. The square root of the evolutionary power spectral density is then decoupled into several time and frequency discrete functions using the proper orthogonal decomposition (POD) interpolation technique, which results in the availability of the fast Fourier transform (FFT) technique in the simulation. Compared with existing decoupling schemes, the POD interpolation achieves a significant efficiency improvement with a slight accuracy reduction. Finally, the simulation formula is further optimized to reduce the number of FFT operations. The accuracy and efficiency of this method are verified with the numerical examples of nonstationary ground motions simulation. Results show that the error introduced by two-step interpolations is fairly small and the simulation agrees with the targets very well. Furthermore, the efficiency generating sample function is significantly enhanced.
1. Introduction
The seismic response of large-scale and long-span structures is seriously affected by the spatially varying characteristics of ground motions [1,2]. Therefore, the seismic response analysis of such structures must adopt multicorrelation seismic inputs. Despite the fact that numerous real earthquake recordings have been gathered, they are not sufficient for a seismic response analysis of structures under multicorrelation seismic excitation due to the limitations caused by the number of strong-motion arrays, seismic environments and soil conditions [2]. As a result, it is of great significance to develop an acceptable multicorrelation ground motion simulation approach for the seismic response analysis of large and long-span structures.
Multicorrelation ground motions can be simulated with a variety of methods [2]. Among them, the spectral representation method (SRM) is simple and accurate, so it is widely used. Hao et al. [3] proposed a spectral decomposition approach for simulating the spatially varying ground motions based on the SRM. Deodatis [4] proposed a nonstationary SRM for the simulation of multivariate nonstationary ground motions described by the evolutionary power spectral density (EPSD). Cacciola and Deodatis [5] proposed an SRM-based method to simulate multipoint correlated ground motions with complete nonstationarity and spectral compatibility. Based on the well-known uniform ground motion model, Wu et al. [6] developed a new model for simulating multicorrelation ground motions for engineering purposes. Bi and Hao [7] utilized the SRM for the simulation of multicorrelation ground motions considering the site effect.
However, the simulation of spatially varying ground motions may involve a large number of simulation points. In this case, the SRM is computationally expensive in memory and time. Therefore, it is necessary to accelerate the simulation with the SRM to adapt to the time history response analysis of large-scale and long-span structures under multicorrelation ground motions. The low efficiency of the SRM lies in the decomposition of the spectral matrix and the summation of cosine terms. In recent years, there has been a large number of studies devoted to improving the simulation efficiency from these two aspects.
In order to accelerate the decomposition of the spectral matrix, the closed-form formation of Cholesky’s decomposition is proposed to prevent the repeating decomposition at each frequency in the wind field simulation [8,9]. Zhao and Huang [10] further provided an enhanced closed-form solution to relax the limiting conditions and enlarge its range of application. However, it is still limited in the exponential coherence function, which may not be satisfied for seismic ground motions. To reduce the number of calculations of direct decomposition, a phase separation method is developed for avoiding complex number operations [11,12]. Some interpolation approaches are also presented to reduce the decomposition amount in the wind field simulation [13,14,15] and the ground motions simulation [11,12].
On the other hand, Yang [16] introduced the fast Fourier transform (FFT) technique to expedite the summation of cosine items in a stationary simulation. Wittig and Sinha [17] further reduced the amount of the FFT in the simulation. In a nonstationary simulation, the uniformly modulated EPSD is widely used for simplification purposes and the FFT technique can be directly utilized. To better reflect the amplitude and frequency of the nonstationary feature, the time-frequency nonseparable EPSD is recommended [18]. Due to the time-frequency coupling function being involved in the summation of cosine items, the FFT is directly unavailable for the non-separable nonstationary simulation. In order to introduce the FFT, Li and Kareem [19] decoupled time-frequency coupling functions with the discrete Fourier transform (DFT) and digital filtering technique. Huang [20] simplified the nonstationary simulation as the simulation of multiple stationary processes with the wavelet decomposition of the nonseparable EPSD. Huang [21] further optimized the simulation by decoupling the nonseparable EPSD with the proper orthogonal decomposition (POD). In addition to the aforementioned typical treatments, some other schemes were developed to decrease the random variables in the simulation. Liu et al. [22] proposed a dimension reduction SRM to simulate multipoint nonstationary ground motions based on the orthogonal expansion of stochastic processes. Ruan et al. [23] further developed the dimension reduction representation for simulating stochastic ground motion fields based on the given wavenumber–frequency spectrum. Although these methods are efficient, they are not tractable and the simulation accuracy may be affected by dimension reduction to some extent.
In order to achieve a simpler and more efficient simulation of nonstationary ground motions, an enhanced interpolation approach is developed for simulating nonseparable nonstationary ground motions based on the SRM in this study. Two steps of interpolations are, respectively, utilized to simplify the matrix decomposition and the time-frequency decoupling. The simulation formula is further optimized to reduce the amount of FFT operations. Although a few errors are introduced, the presented approach is highly efficient. The rest of this article is arranged below as follows: Section 2 reviews the basic theory of the SRM-based nonstationary ground motions simulation. The presented approach containing two steps of interpolations and an FFT optimization is introduced in Section 3 in detail. Then, two numerical examples of a nonstationary ground motion simulation are shown in Section 4. Finally, conclusions are drawn in Section 5.
2. Theoretical Foundation
2.1. Description of Ground Motion Fields
The spatially variable earthquake motion can be considered as n-variate zero-mean nonstationary Gaussian vector process (the superscript denotes the transpose), which can be characterized by its EPSD matrix given by [24]
where is the circular frequency and is the time; the diagonal element is the auto-EPSD of the jth element process and real function; the off-diagonal element is the cross-EPSD between the jth and kth element processes and can be determined by
where is the coherence function between the jth and kth element processes.
The EPSD matrix can be determined by the auto-EPSD of each element process and the coherence function between two-element processes. The auto-EPSD represents the time-varying amplitude and frequency content of earthquake motions, which can be calculated directly from recorded ground motion time histories or provided by an existing empirical or theoretical EPSD model [18,25,26]. The fluctuation in auto-EPSD at various sites may be used to account for the spatial variability of earthquake motions due to the ‘attenuation effect’.
The coherence function captures the spatial variability of earthquake motions caused by the ‘incoherence effect’, ‘wave-passage effect‘ and ‘site effect’. Therefore, the coherence function can be represented as [1,27]
where denotes the module of a complex number; and , respectively, denote the exponential function and imaginary unit; is the complex phase of the coherence function; is the lagged coherence function describing the ‘incoherent effect’; is the phase describing the ‘wave-passage effect’ given by
in which is the wave velocity and is the distance between the jth and kth locations projected in the direction of the seismic wave propagation; is the phase describing the ‘site effect’ and given by
in which and are, respectively, the frequency response functions of the first filter corresponding to the jth and kth locations.
Besides EPSD, can also be characterized by the time-varying correlation function. The cross-correlation function between the jth and kth element processes can be represented by
where is the time lag.
2.2. SRM-Based Nonstationary Ground Motions Simulation
The simulation of nonstationary ground motions based on the SRM has been widely developed and applied [4]. The basic theory is briefly given as follows:
The EPSD matrix is a Hermitian matrix with the feature of being non-negatively definite. It may be decomposed into the following product using the Cholesky decomposition at each time-frequency point:
where the superscript signifies the complex conjugate and is the decomposed EPSD matrix written as
The diagonal elements are both real and non-negative with . The off-diagonal elements are typically complex with and can be expressed as
where is the phase of and generally expressed as
in which the letters ‘Im’ and ‘Re’, respectively, stand for imaginary and real parts. However, based on the definition of the complex phase, its value should fall into the range of , while exceeding the range of in Equation (11). Thus, Equation (11) cannot be used to calculate the complex phase.
Based on the spectral decomposition results, the samples of the jth element process can be generated by [4]
where is the frequency increment; is the cutoff frequency; is the total number of discretized frequencies; ; and are a set of independent random-phase angles uniformly distributed in the range .
Obviously, the simulation’s efficiency is seriously restricted by the decomposition of the EPSD matrix and the summation of trigonometric items. Although some effective schemes are available for improving the simulation’s efficiency, they are still insufficient due to their limitations in their use or complexity of processing.
3. Enhanced Interpolation Approach
In this section, an enhanced interpolation approximation approach with three treatments was proposed. Firstly, the interpolation scheme was used to accelerate the matrix decomposition. Secondly, the square root of EPSD was decoupled using the POD interpolation technique. Finally, the summation formula was further optimized to decrease the number of FFT operations.
3.1. Decomposition of EPSD Matrix Based on Interpolation
The phases generally admitted the requirement that for the ground motion [1]. Thus, the decomposition of the complex matrix could be simplified as the decomposition of its real matrix to obtain an immediate decomposition [12], i.e.,
where
Based on Equations (2) and (3), can be further represented as
where
and the lagged coherence matrix is expressed by
Because is also a Hermitian matrix, it can be decomposed as
On the basis of Equations (14), (18) and (21), we had
To sum up, the decomposed EPSD can be obtained by
Obviously, the Cholesky decomposition along time and frequency has been simplified as that of along frequency.
As shown in Equation (21), the Cholesky decomposition of the lagged coherence matrix had to be performed at each frequency. When a large number of ground motion simulation points were involved, the calculation became prohibitive. As a result, the interpolation approximation strategy is commonly utilized to decrease the Cholesky decomposition times. Considering that the elements of are uniformly varying and continuous functions of for the seismic motion, the uniformly distributed frequency interpolation points , are selected and calculated with
where is the frequency interpolation point number; . As long as the decomposition results at the interpolation points are acquired, the interpolation technique, such as the spline interpolation, Lagrange interpolation and Hermite interpolation, may be used to obtain the results at additional frequency points. The Hermite interpolation was utilized in this study because it ensured continuity and differentiability at the interpolation locations.
3.2. Time-Frequency Decoupling with POD Interpolation
Some approaches, including DFT [26], POD [21,28] and non-negative matrix factorization [29], were utilized to factorize the time-frequency coupled functions or for invoking the FFT into the nonstationary simulation. However, these schemes would be rather time-consuming for the simulations with extended durations and high sample frequencies. The POD interpolation was utilized for time-frequency decoupling in this section.
Due to the auto-EPSDs being continuous functions of and for the ground motions, the uniformly distributed time-frequency interpolation points were selected and determined as
where and are, respectively, the number of the time-frequency interpolation points along frequency and time directions, and ( is the amount of time instants of samples).
In a matrix, the square root of EPSD at the time-frequency interpolation points is given as
This matrix’s columns can be thought of as column vectors. A set of optimal orthogonal bases for these vectors can be obtained by the following eigenvector decomposition
where and are, respectively, the th eigenvector and eigenvalue; and is the correlation matrix of these column vectors, which could be calculated using
Additionally, the principal coordinates could be determined by
where is the th projection vector of the column vectors.
By reorganizing the eigenvalues in descending order, the eigenvalues at lower orders containing more energy were reserved. could be roughly recreated by
where the first items were chosen to meet the accuracy requirement. Therefore, those coupled functions were factorized as
where and are, respectively, the discrete functions corresponding to and .
Once and were determined, the interpolation approach could be used to approximately estimate and . Then, the square root of the EPSD at all time-frequency points could be reconstructed by
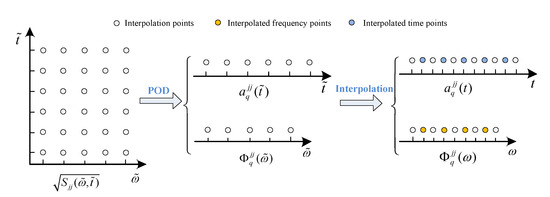
Figure 1 depicts the aforementioned decoupling procedure using POD interpolation. It can be seen that there were mainly three steps for the decoupling procedure. First, the square root of the EPSD at the time-frequency interpolation points was calculated. Then, was decoupled as some time and frequency functions and with POD. Finally, the time and frequency functions and could be obtained with interpolation.
Figure 1.
POD interpolation procedure.
POD is only utilized for dimensional small matrices and only one-dimensional interpolations are required in this approach while it was on dimensional matrices in the existing study [21,28]. As a result, POD interpolation outperformed previous time-frequency decoupling approaches.
3.3. Optimizing FFT Operations
With the help of the time-frequency decoupling, the FFT algorithm could be readily introduced to accelerate the summation of trigonometric items in the simulation. Based on Equations (24) and (34), Equation (13) could be reformulated as
It can be seen that the FFT could be used to calculate the summation with respect to l in Equation (35) for each j, k and q. To generate an n-variate ground motion sample, a total of FFT operations was required.
In order to further optimize the FFT operations, Equation (35) could be recast by exchanging the summation order, i.e.,
In this moment, the FFT would be used for the summation with respect to l only for each j and q. Thus, the number of FFT operations was reduced to . Details about the usage of FFT in Equation (36) are given in Appendix A.
3.4. Complete Simulation Procedure
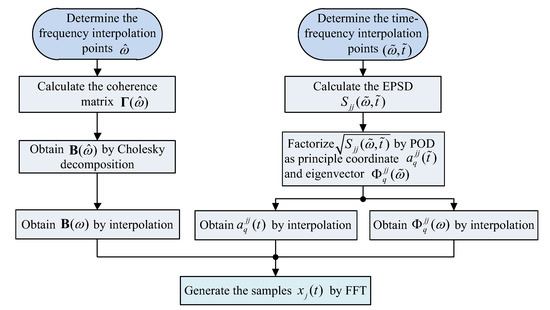
Figure 2 depicts the flowchart of the suggested simulation approach, which consisted mostly of the following five steps:
Figure 2.
Flowchart of the presented approach.
Step 1: Determine the interpolation point number , and . Then, obtain the frequency interpolation points with ordered frequency and the time-frequency interpolation points with ordered frequency and time .
Step 2: Based on the given spectral and coherence models, calculate the lagged coherence matrix and the EPSD at those interpolation points.
Step 3: Execute the Cholesky decomposition for to obtain ; use POD to factorize into the principle coordinate and eigenvector .
Step 4: Obtain by interpolating each element of ; obtain and by, respectively, interpolating and .
Step 5: Generate the simulated samples with Equation (36) and the FFT.
In summary, only Cholesky decompositions, PODs and FFTs were required in the whole simulation procedure. Furthermore, POD was only executed on the dimensional matrices. Therefore, the proposed approach was remarkably efficient for simulating spatially varying ground motions.
4. Numerical Examples
In this section, two simulation examples about nonstationary seismic acceleration fields were given to demonstrate the effectiveness of the suggested method. In the first example, the nonseparable spectrum was used, the influence of the selection of simulation parameters on the simulation accuracy was discussed in detail and the simulation efficiency was studied. The second example was intended to investigate the method’s applicability to the nonuniformly modulated spectrum.
4.1. Nonseparable Spectrum
Consider a nonstationary earthquake acceleration field with a total of 50 evenly distributed simulation points. The distance between two adjacent simulation points is 15 m. It is assumed that each simulation point has the same autospectrum described by a nonseparable one-sided spectral model [18], which is given by
where . The coherence function adopts the following model [30,31], i.e.,
where depicts the distance between the jth and kth locations; is the wave propagation velocity in the direction of seismic wave propagation; the parameters are selected as m; m/s; ; ; m/s; ; Hz.
The basic parameters used in the simulation are the total time , the cutoff frequency , the time step and the frequency step .
4.1.1. Parametric Analysis
The error of the suggested method was mostly due to the approximations of POD interpolation to and the interpolation to Cholesky’s decomposition results . Thus, two kinds of errors were defined to study the influence of parameter selection on the simulation accuracy. The POD interpolation error is defined as
where is the target value calculated by the spectral model and is the approximate reconstruction using the POD interpolation. The parameters involved in the POD interpolation were the selected POD mode number and the number of time and frequency interpolation points and .
The interpolation error of Cholesky decomposition is defined as
where is the interpolation result of the element obtained by the Cholesky decomposition of ; is the element obtained by the Cholesky decomposition of ; is the relative error between and . Obviously, the interpolation error of Cholesky decomposition was only related to the number of frequency interpolation points .
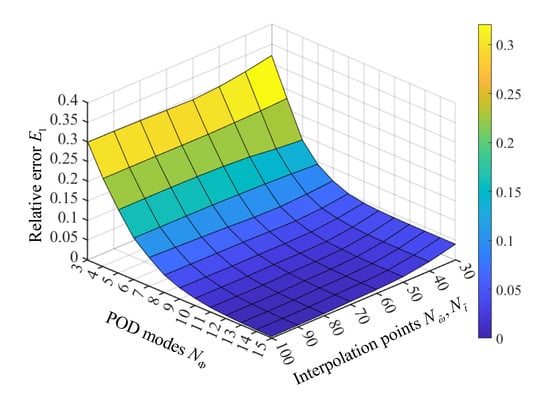
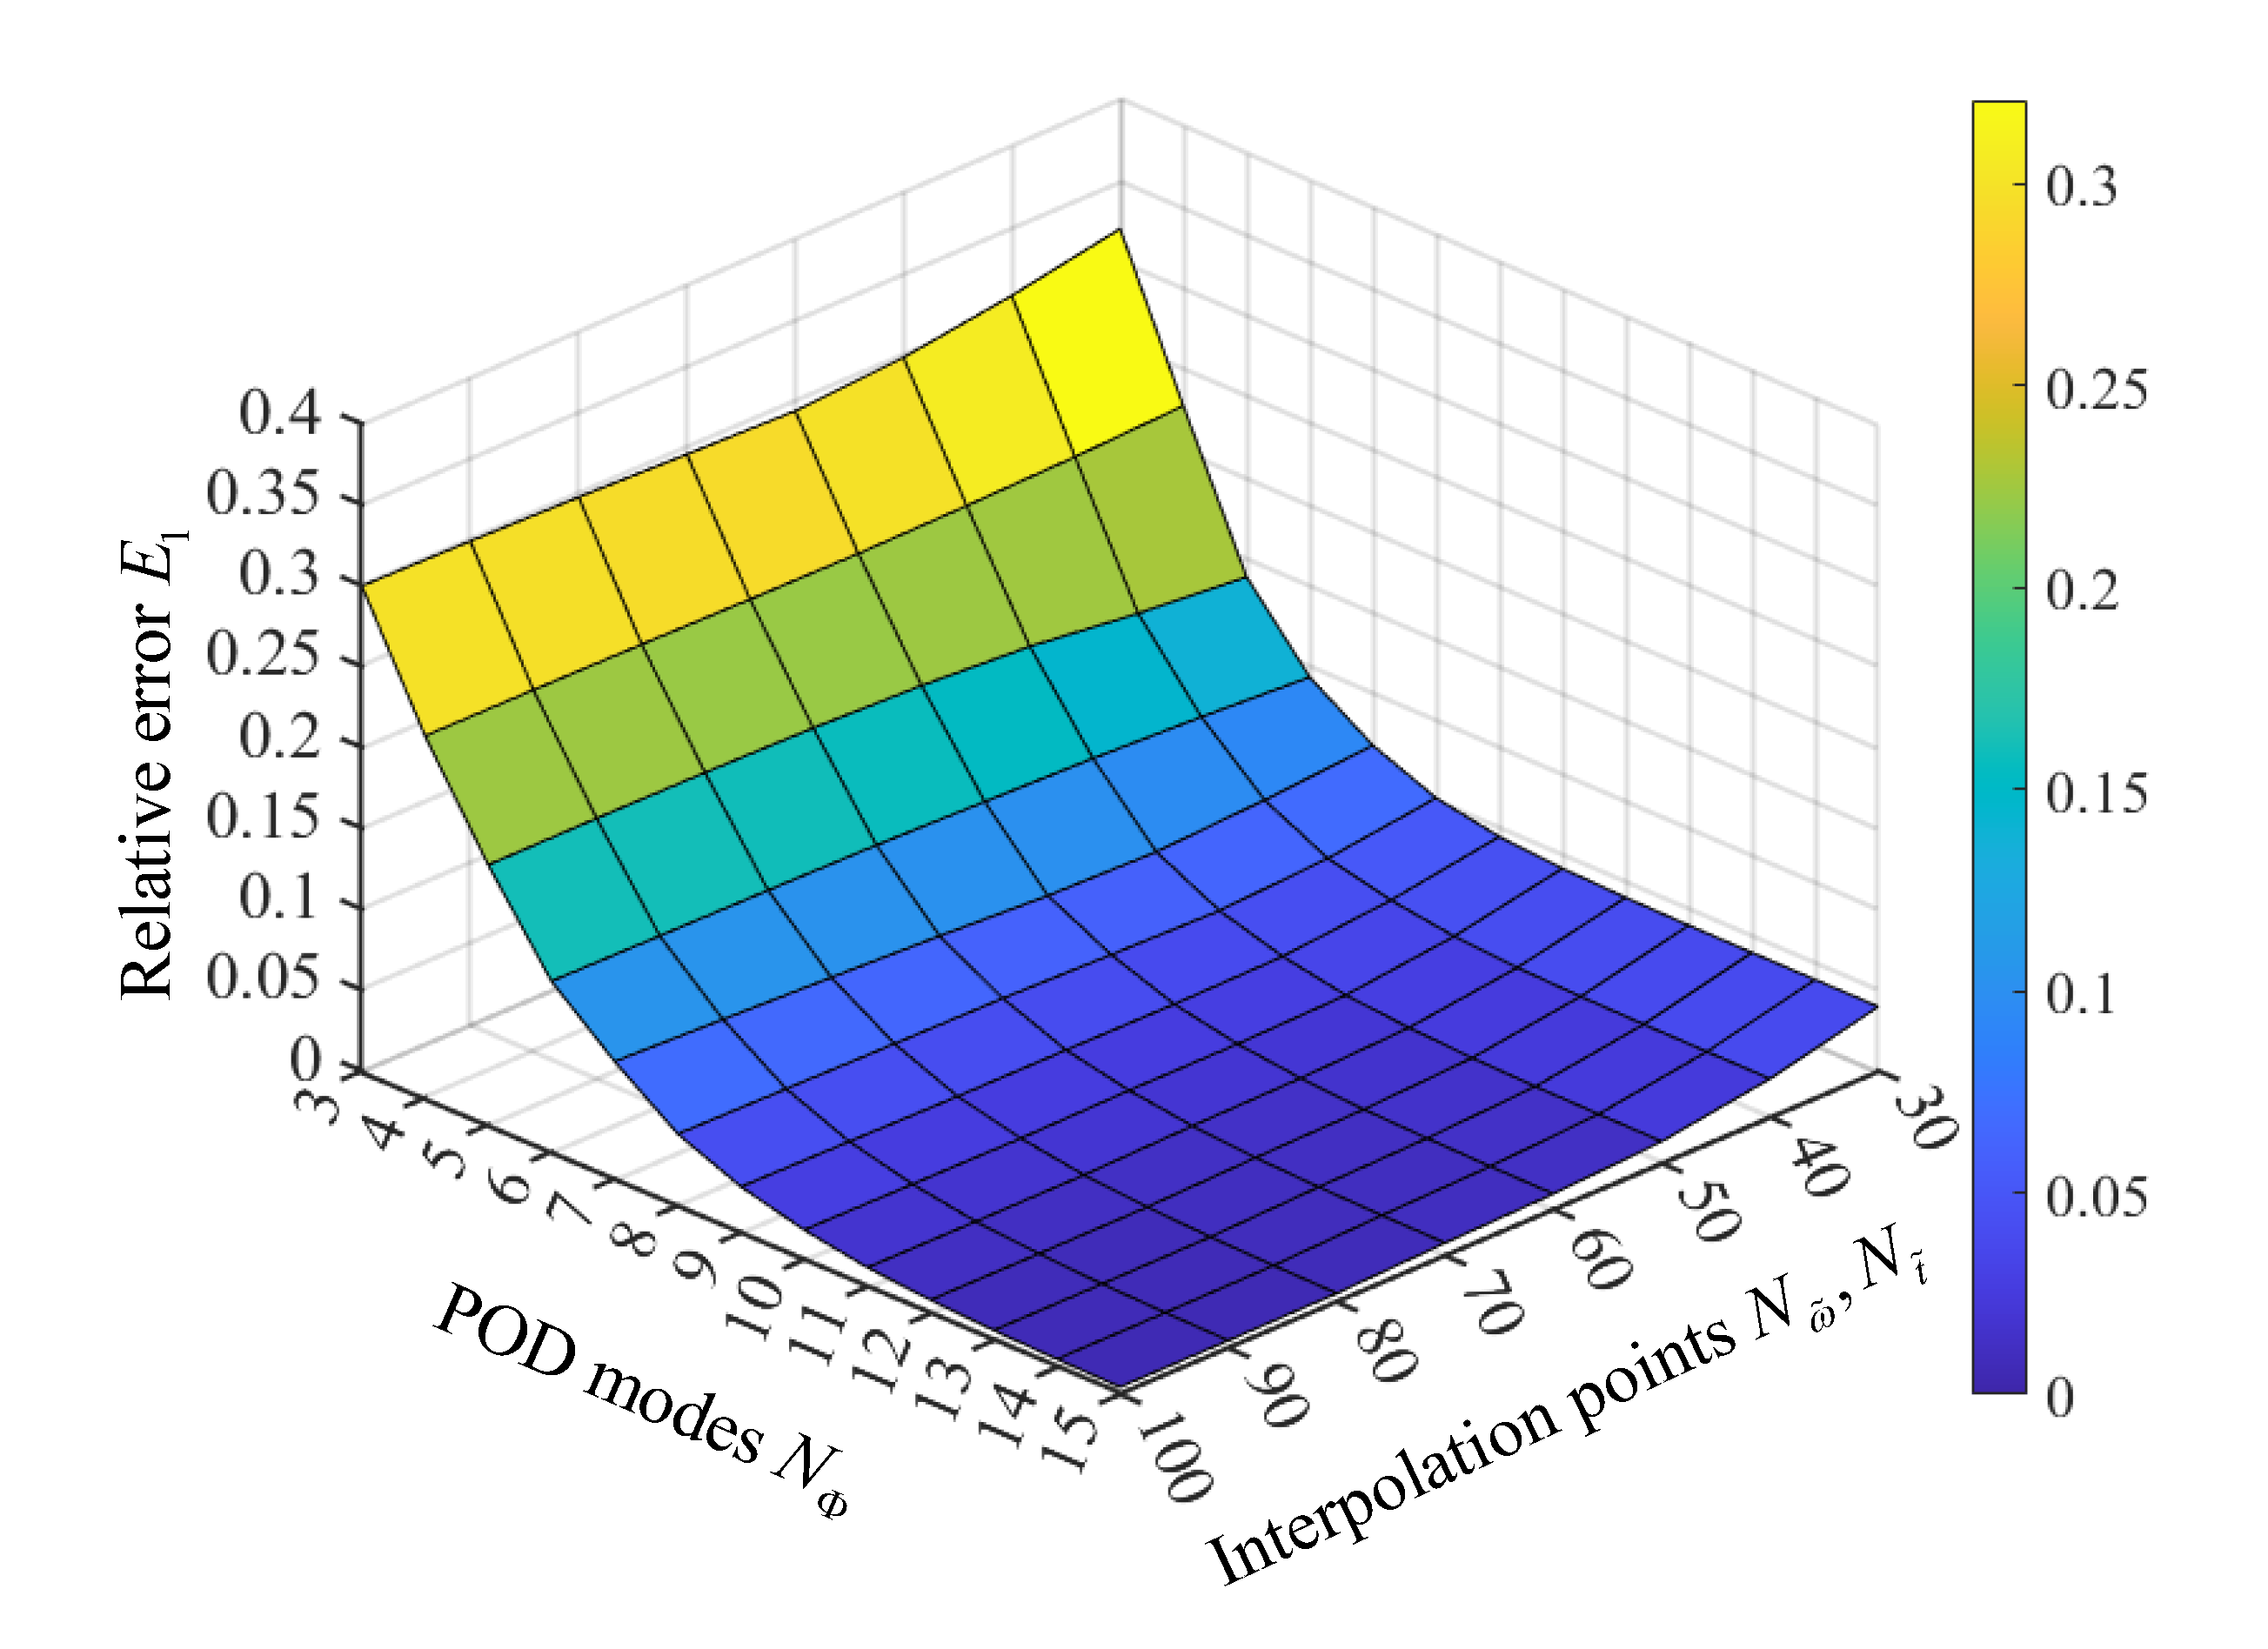
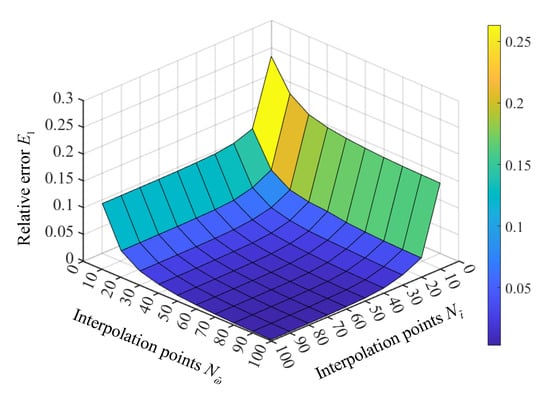
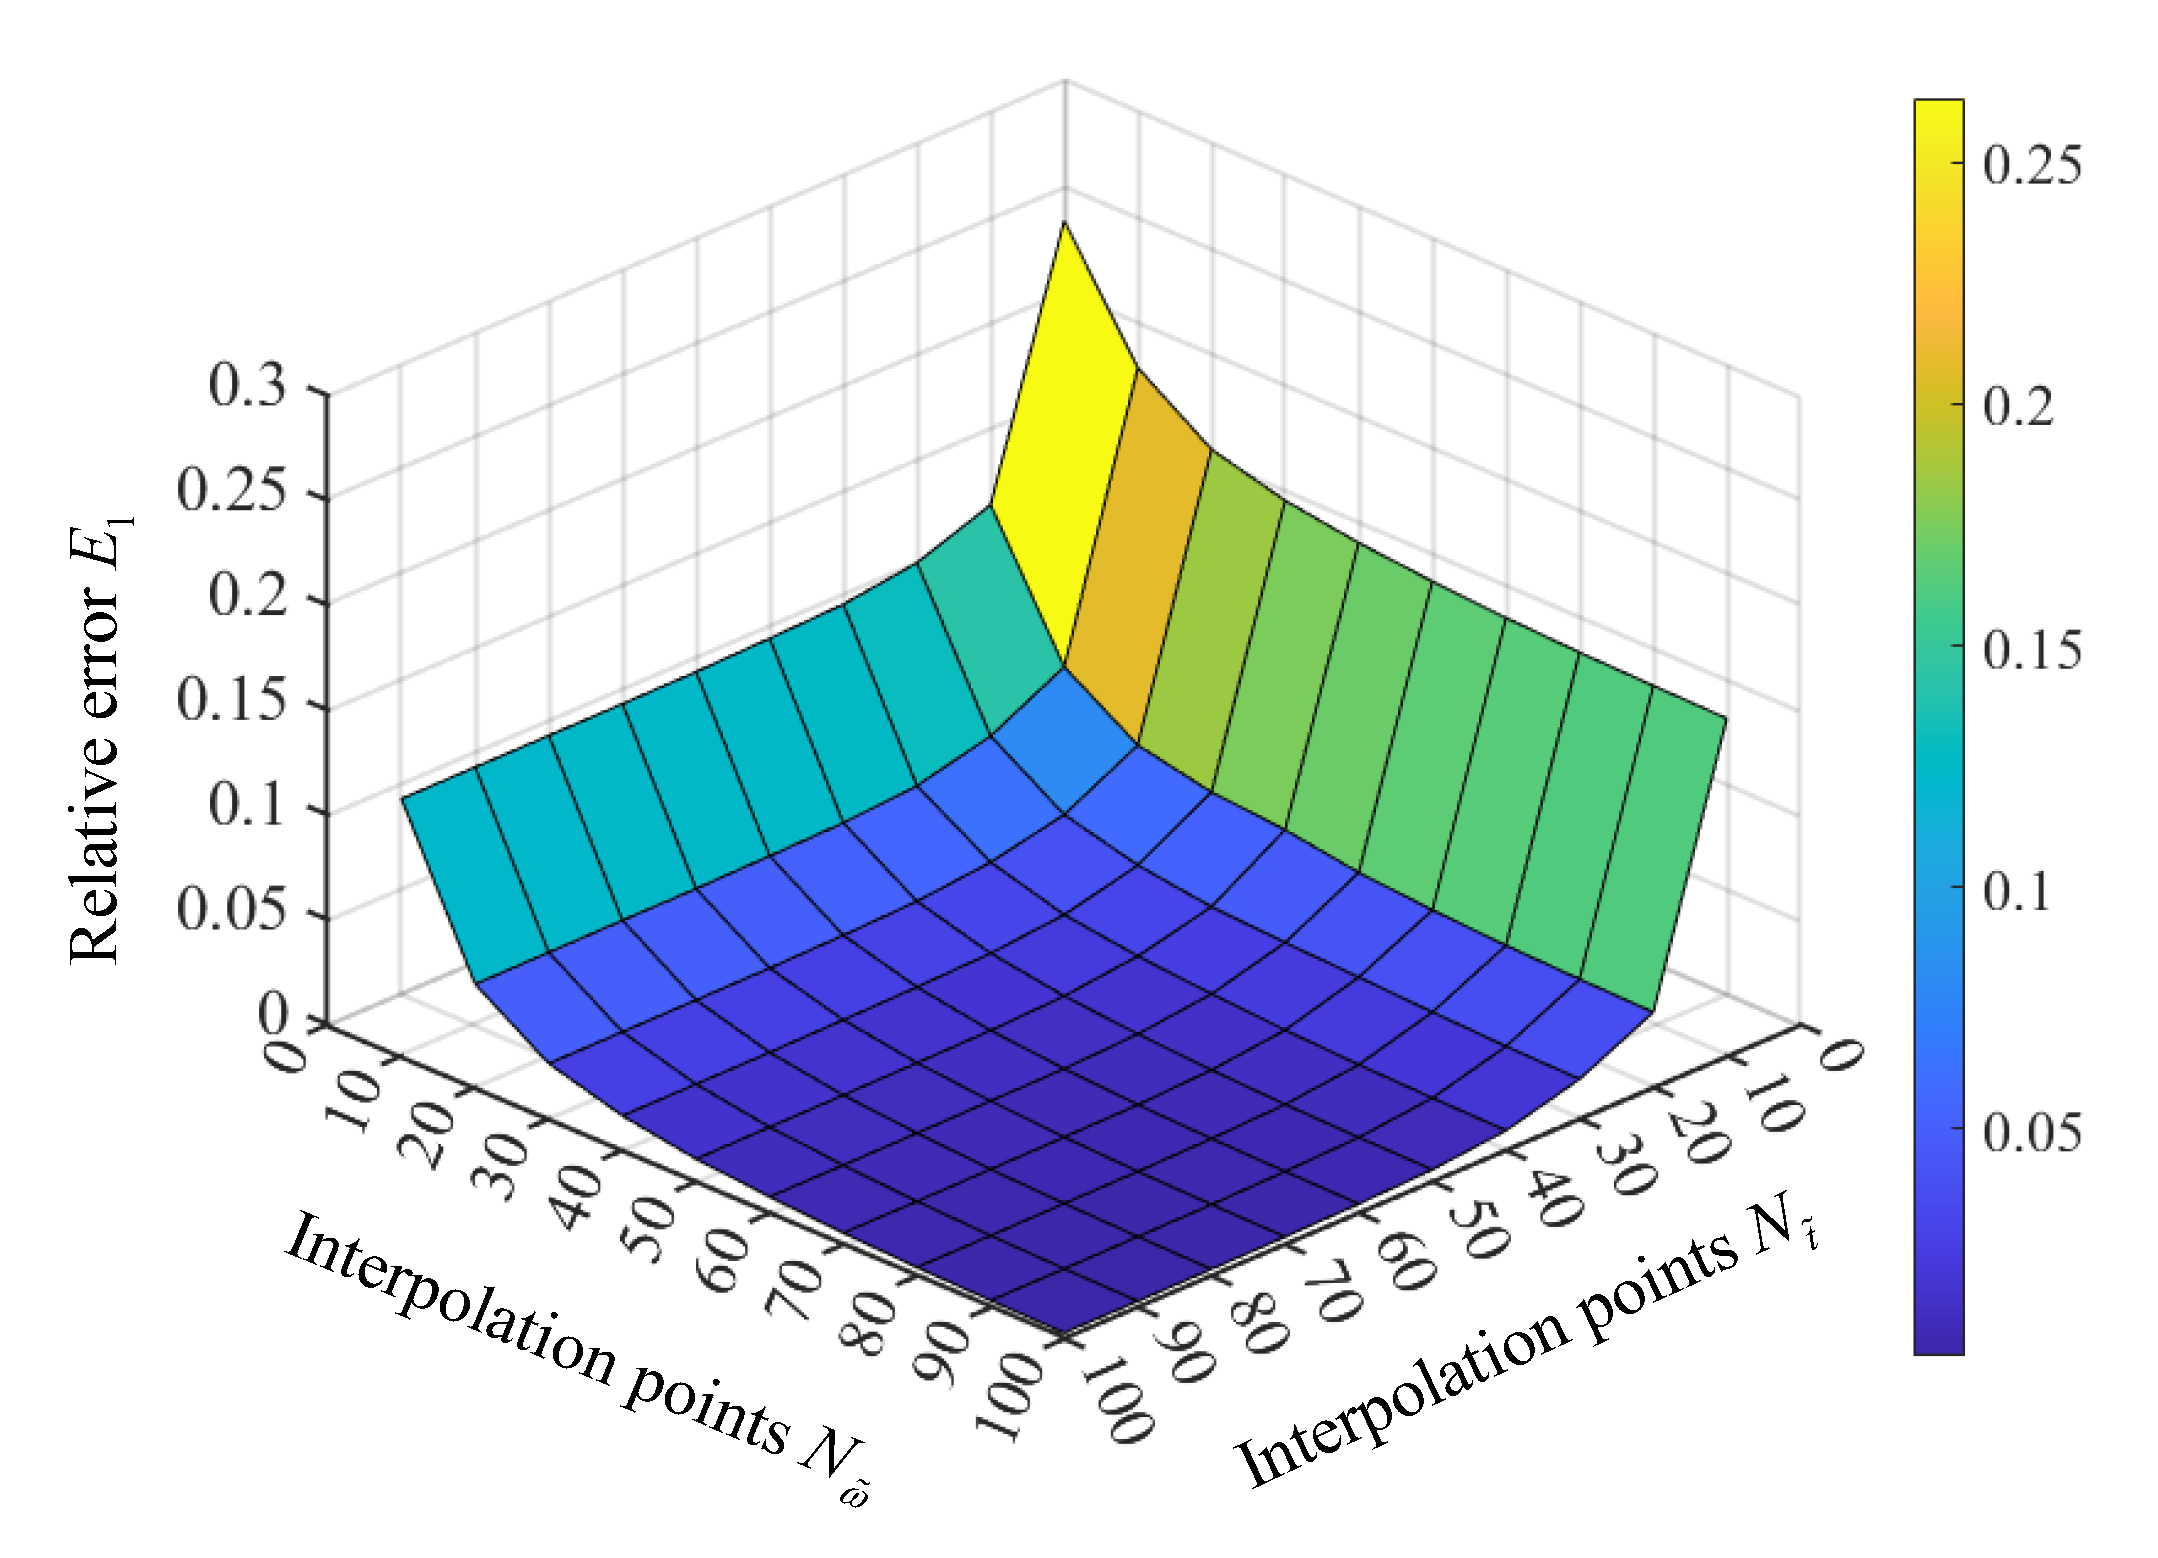
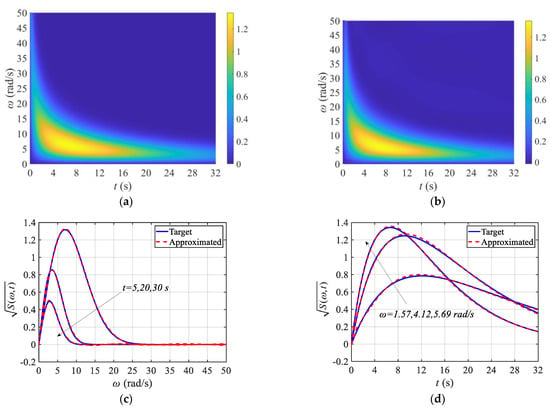
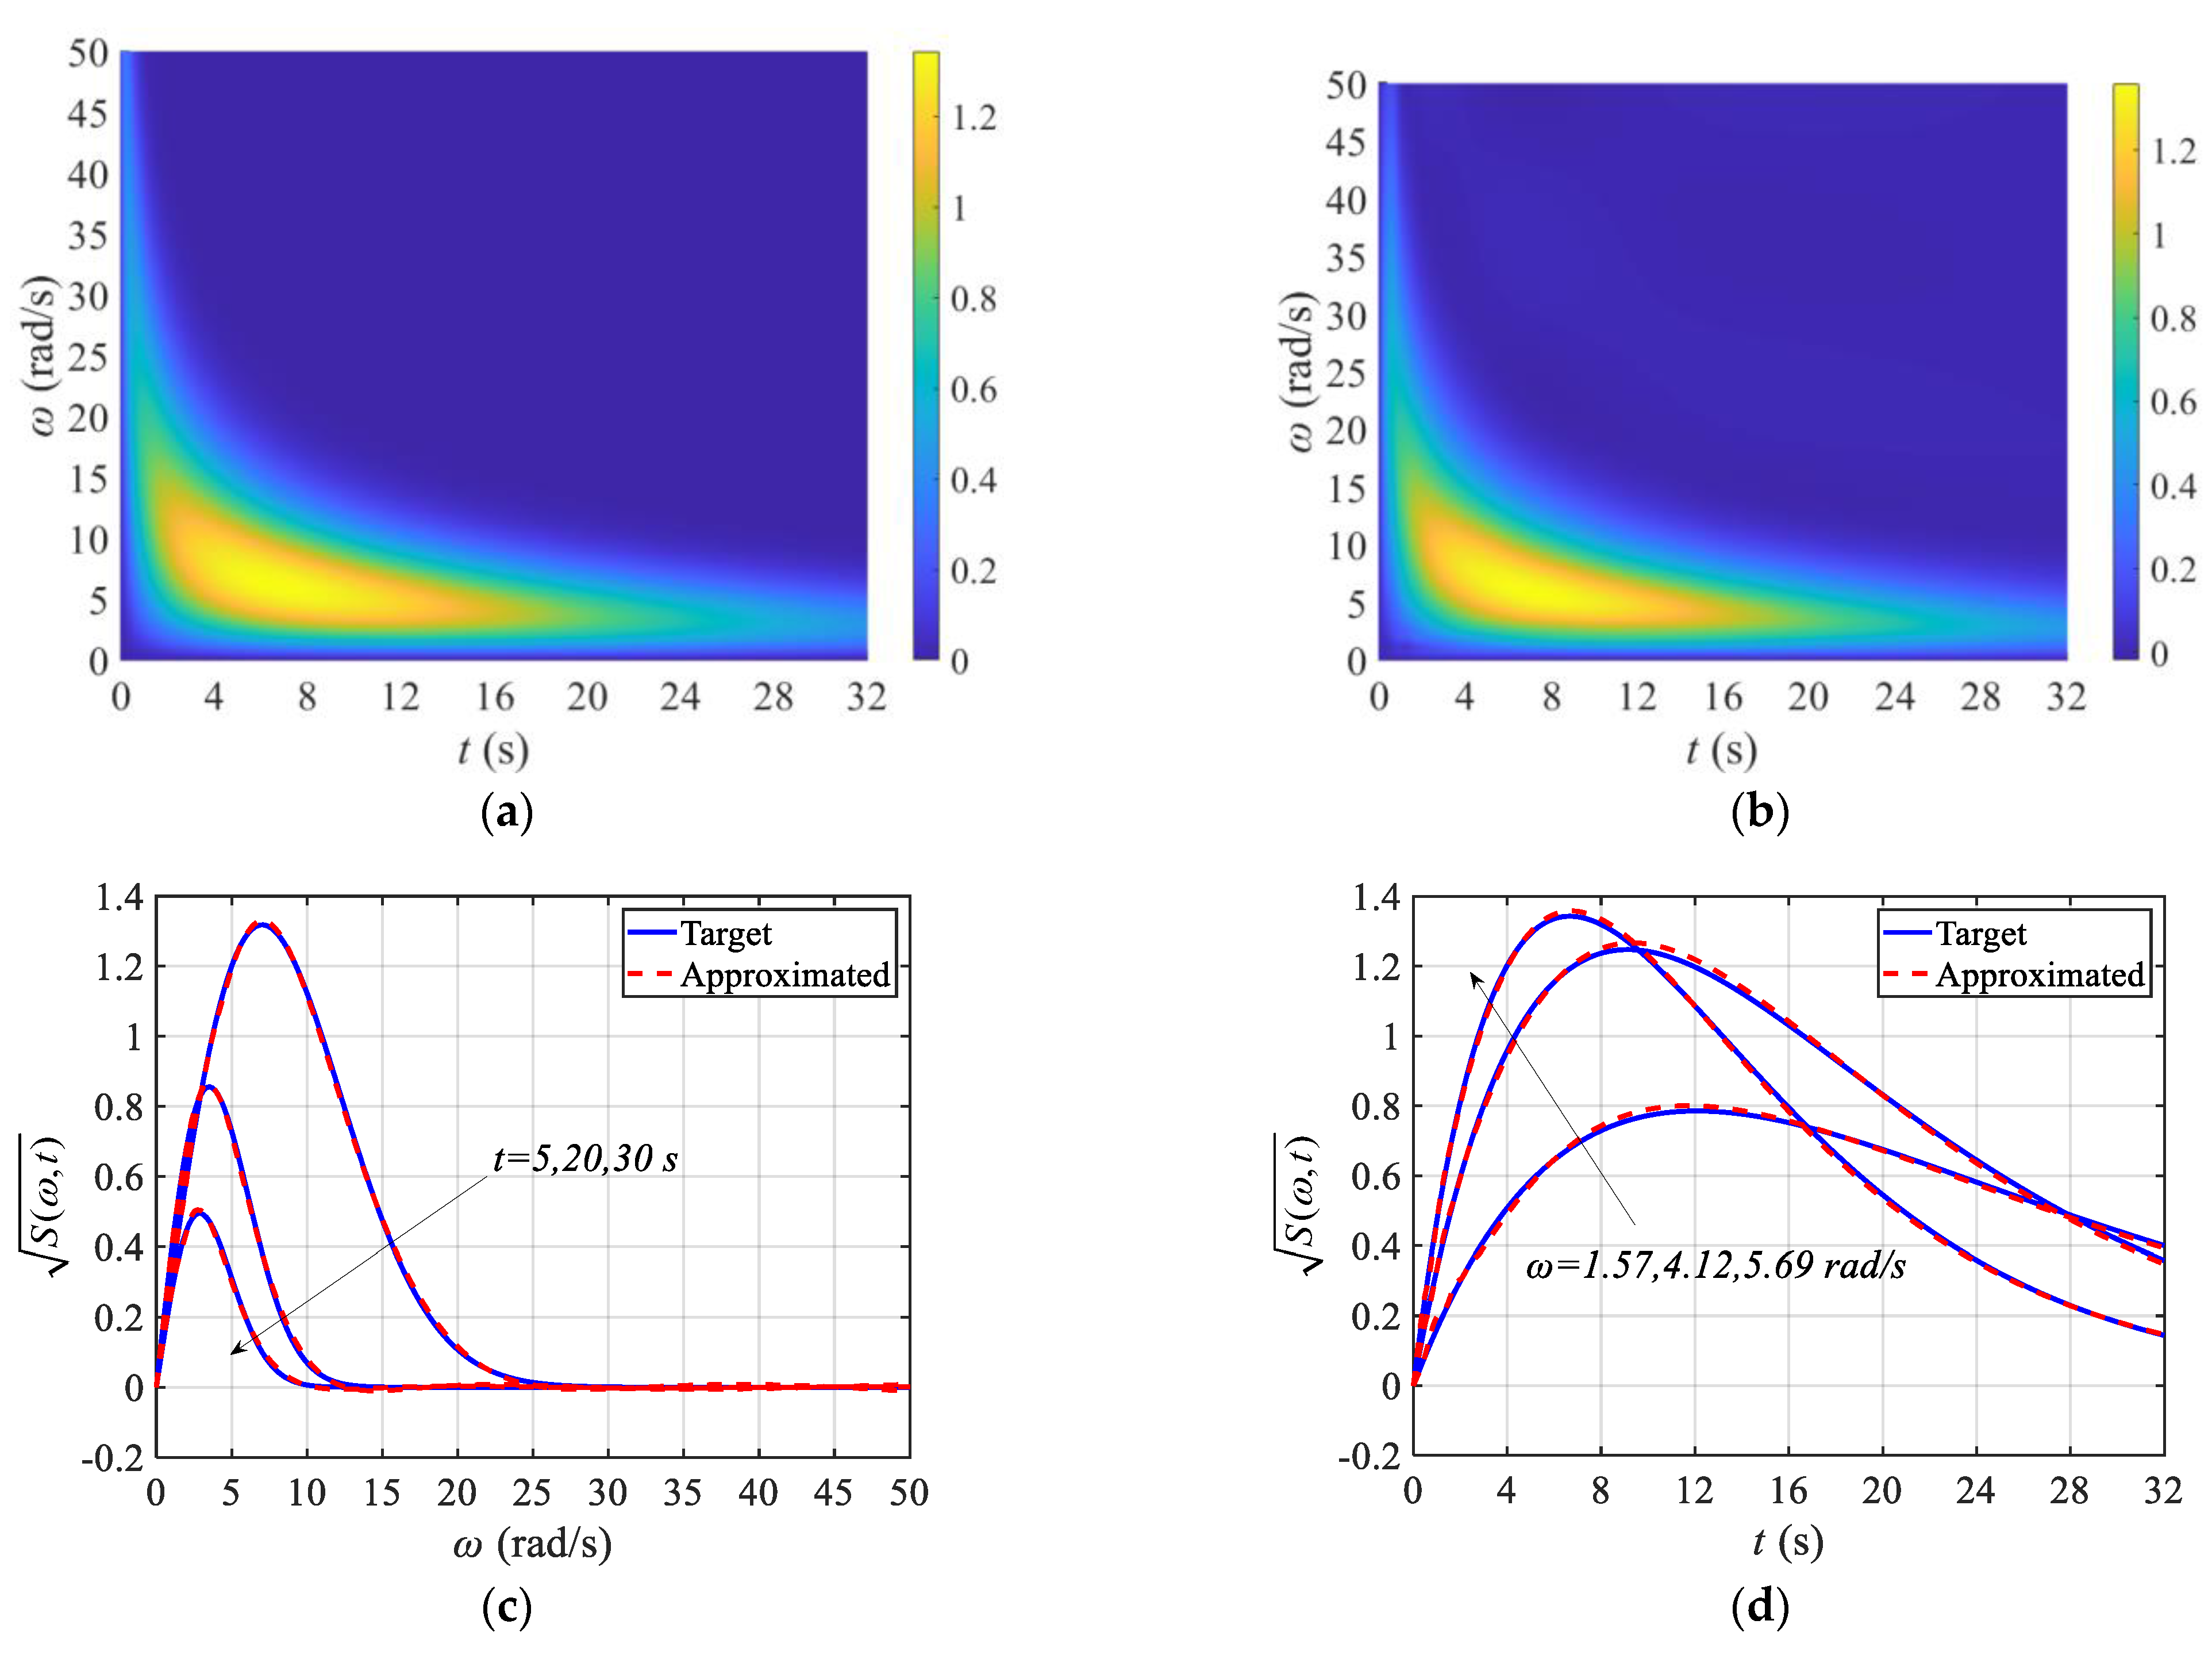
Figure 3 shows the effect of the mode number and the time and frequency interpolation point numbers and on the POD interpolation accuracy, where the number of time interpolation points was the same as the number of frequency interpolation points. It was discovered that the considered mode number had a greater impact than the interpolation point number. With the increase in , the error decreased rapidly. When , the POD interpolation error stabilized and kept at a low level (). Figure 4 shows the effect of different time and frequency interpolation points on the POD interpolation accuracy. As can be seen, the number of time interpolation points and the number of frequency interpolation points had the same effect on POD interpolation, and the more interpolation points, the smaller the error. Within the acceptable error range (), and were enough for obtaining a good estimate result. Based on Equations (33) and (34), the approximate reconstruction could be obtained with POD interpolation, as shown in Figure 5b. The target could be calculated with Equation (37), as shown in Figure 5a. There was no discernible difference between the two results, as can be seen. Therefore, the decoupled function obtained with POD interpolation could describe the target function well.
Figure 3.
Effect of interpolation point number and POD mode number on decoupling accuracy.
Figure 4.
Effect of time-frequency interpolation point number on decoupling accuracy.
Figure 5.
Comparison of target and approximated : (a) exact ; (b) approximated ; (c) frequency slice; (d) time slice.
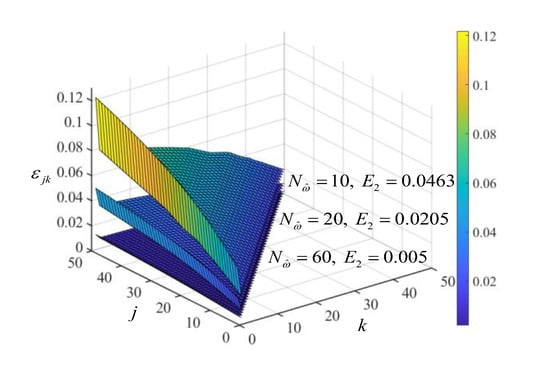
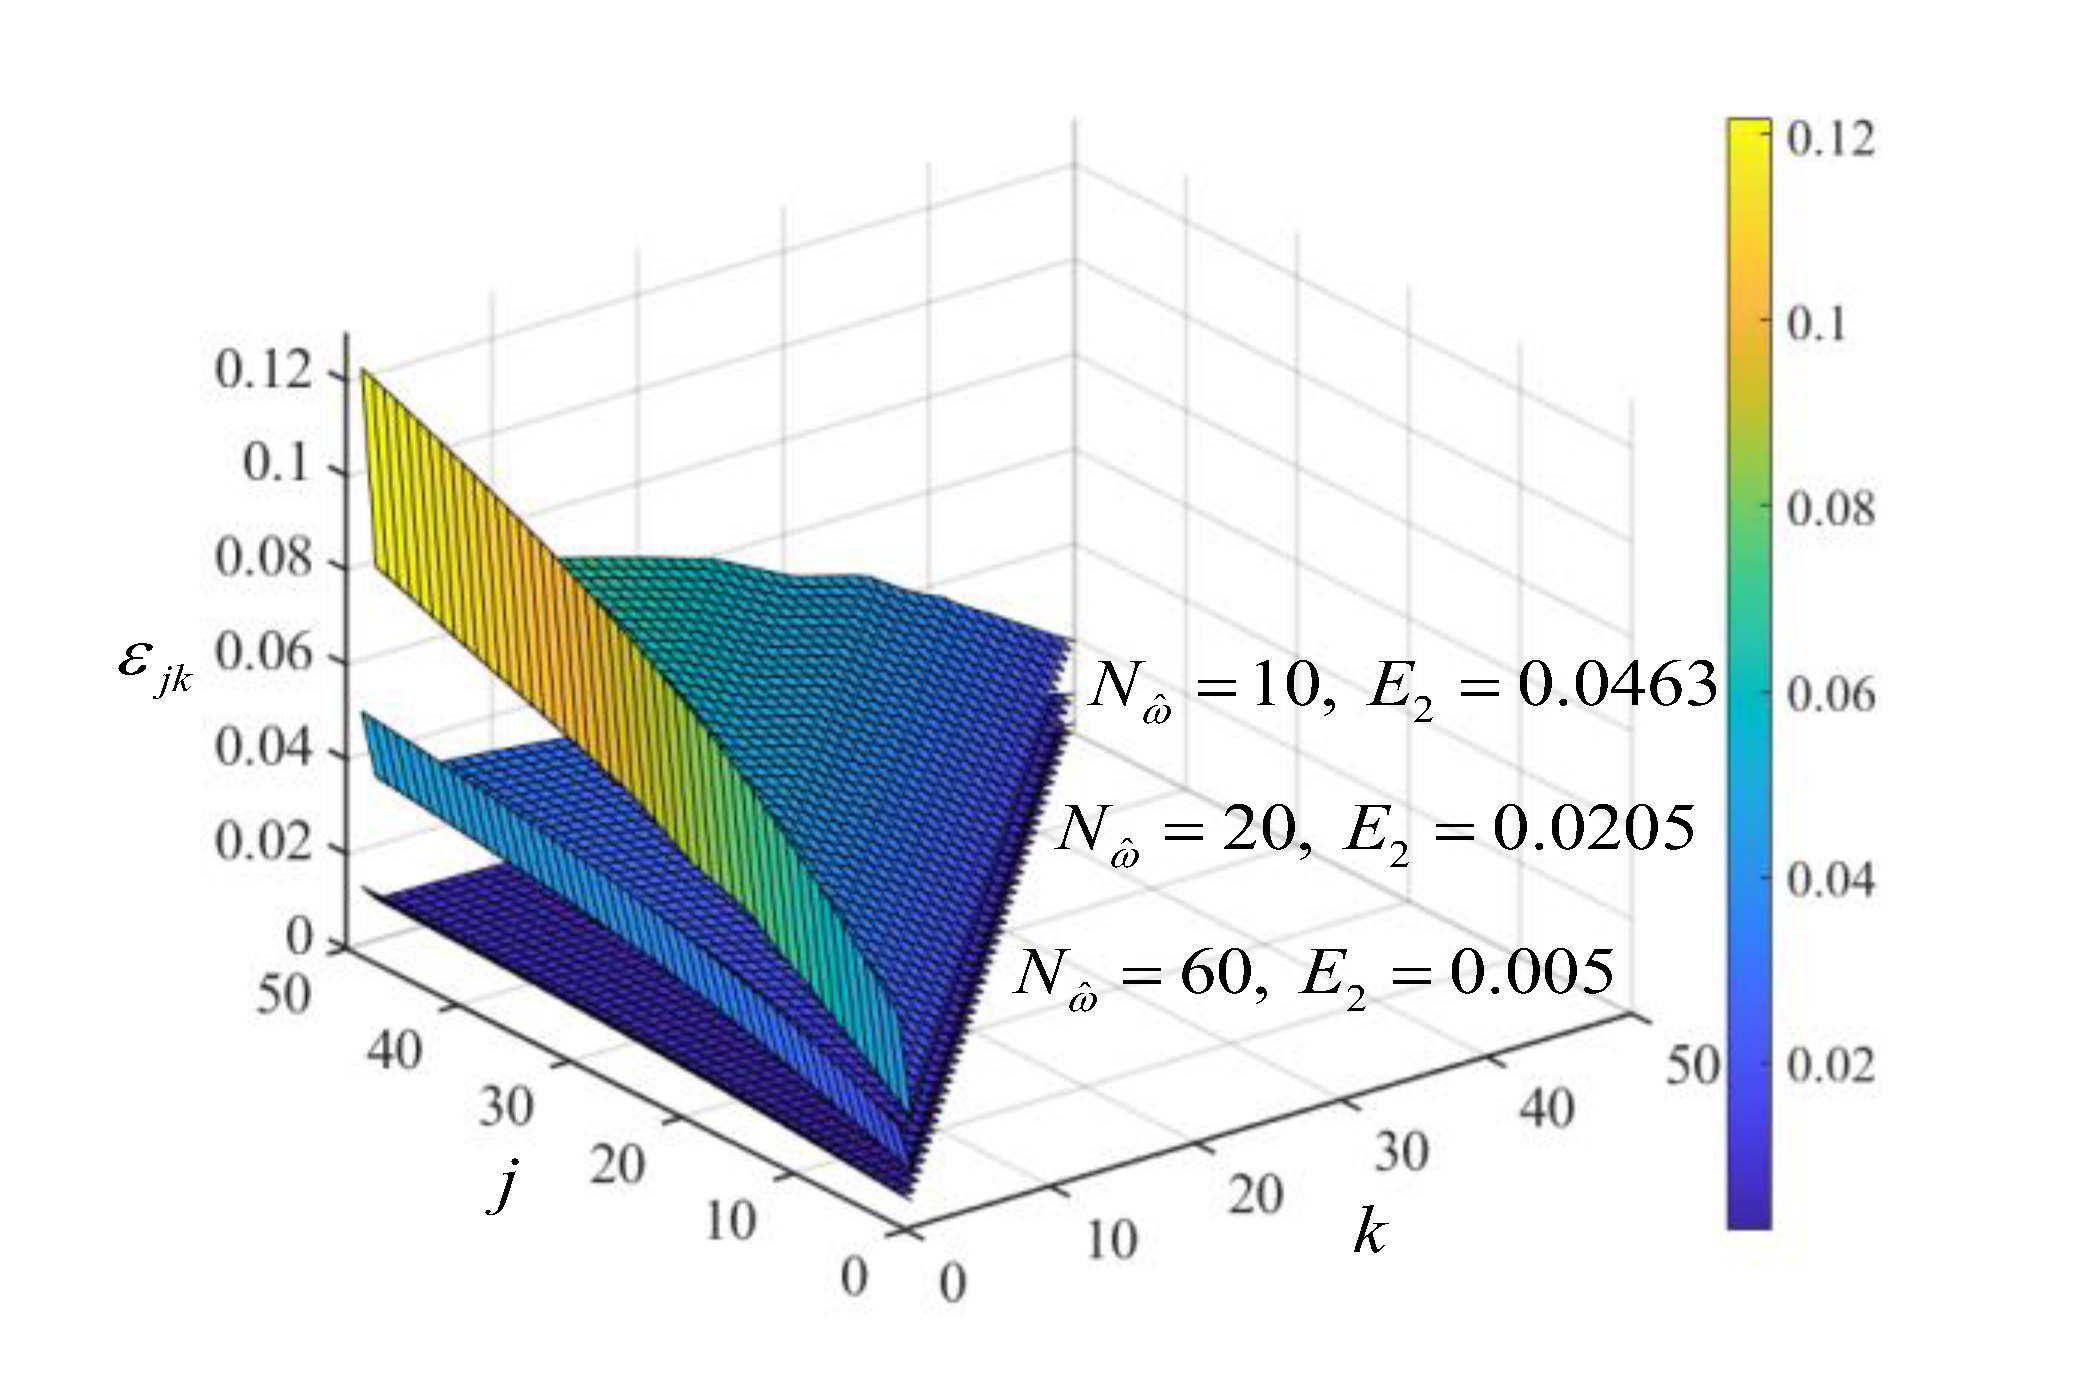
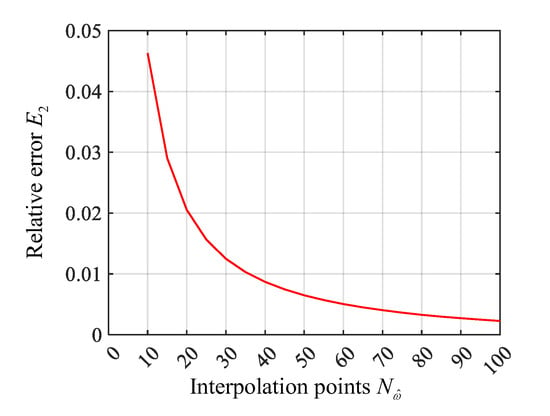
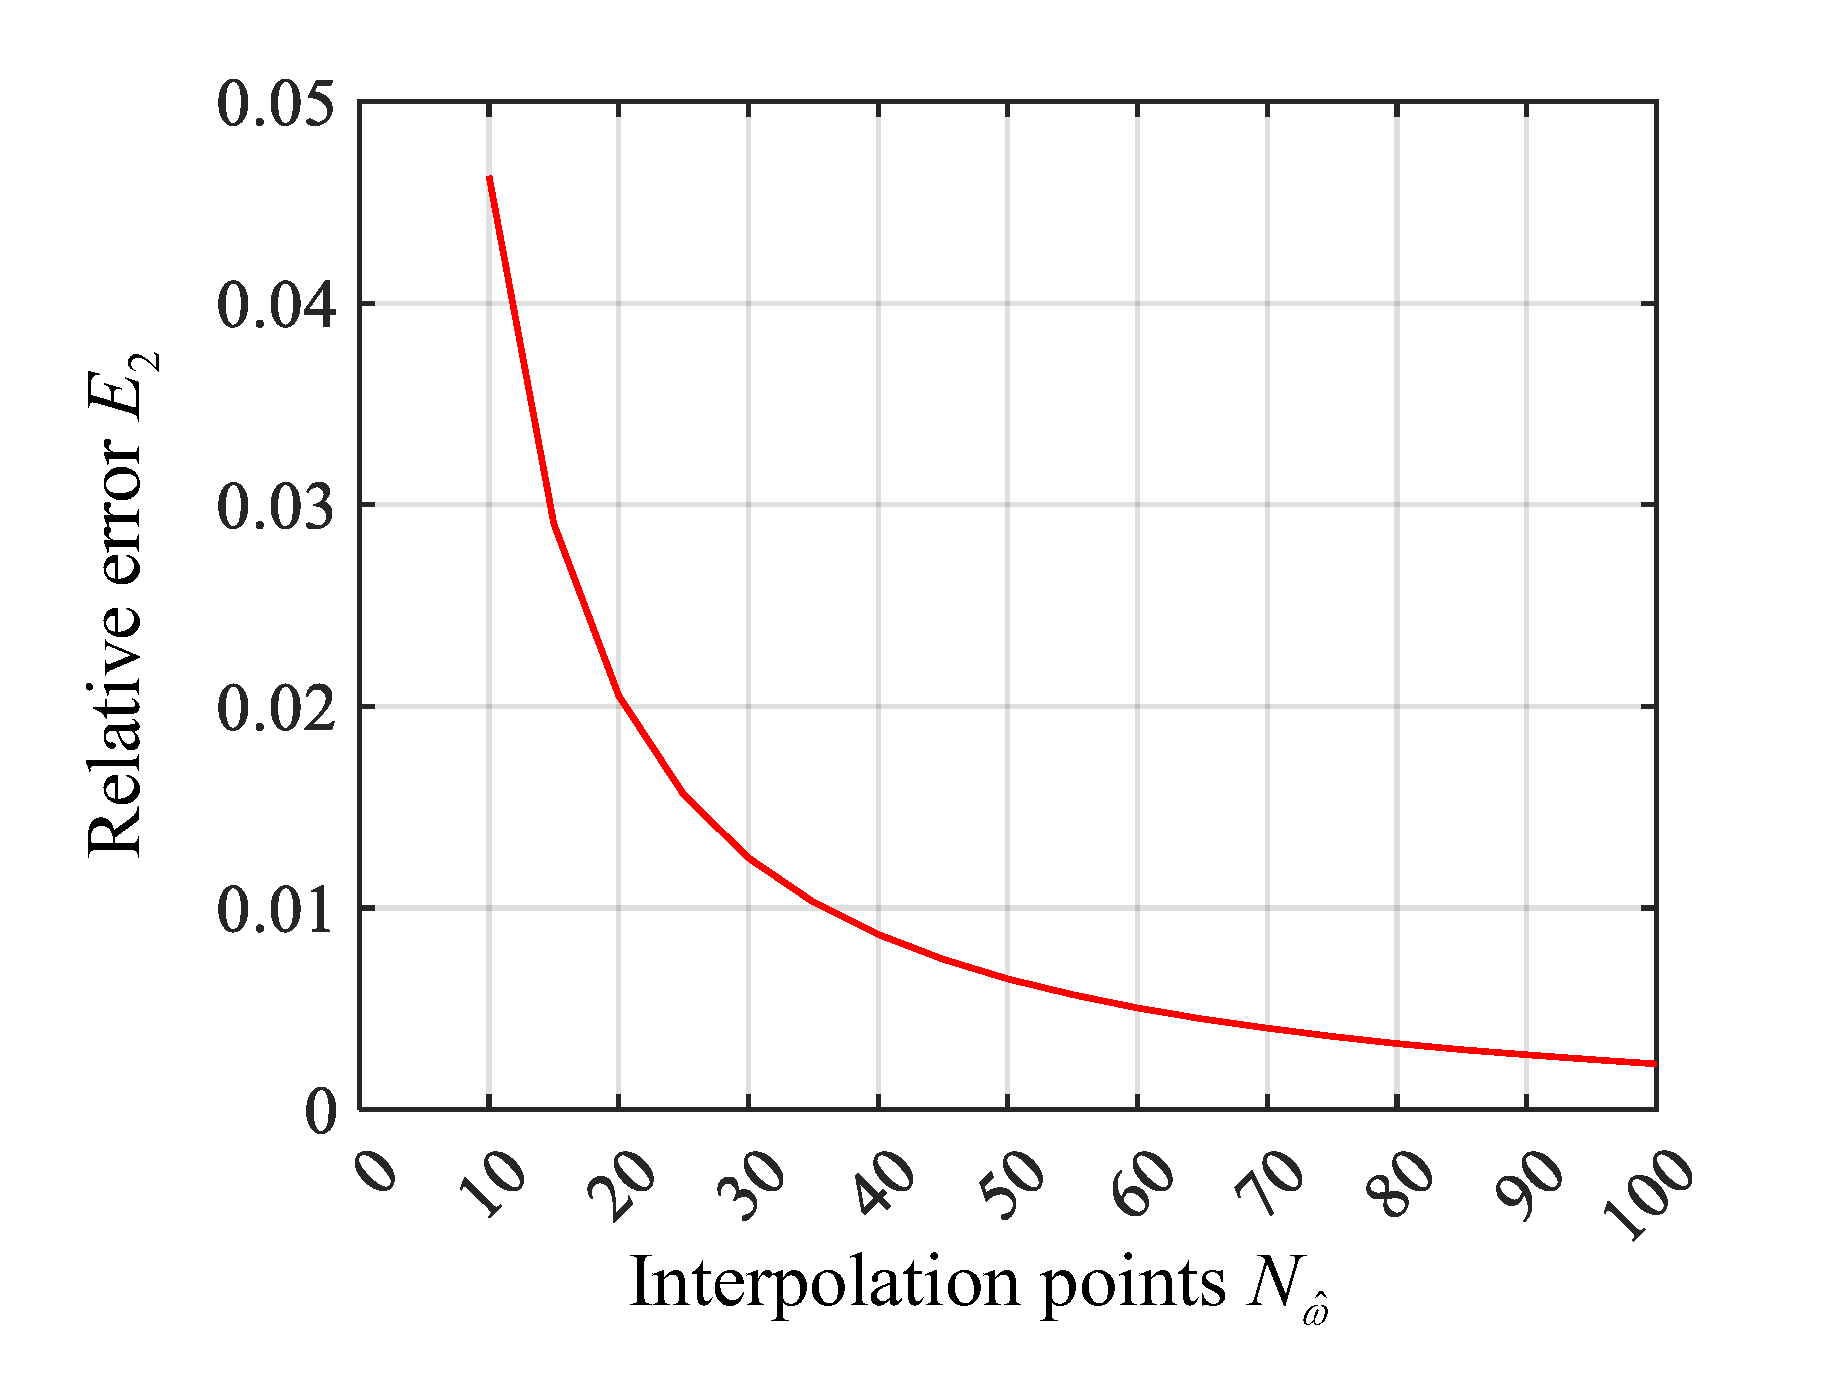
The interpolation error of the Cholesky decomposition result could be calculated with Equations (42) and (43). Figure 6 shows the relative error and the average relative error for three specific frequency interpolation points . It can be seen that the interpolation errors of the elements of in the first column of the lower triangular matrix were evidently larger than that of other elements. This may be because these elements changed drastically more with frequency, and the corresponding interpolation accuracy was relatively worse under the same interpolation points. However, its impact on the simulation results was minimal. As can be seen, the interpolation accuracy for met the requirement of . Further, the influence of frequency interpolation points on the average relative error is displayed in Figure 7. It can be seen that the average relative error decreased gradually with the increase in frequency interpolation points and the accuracy met the requirement of when .
Figure 6.
Relative error under three typical interpolation points.
Figure 7.
Effect of the interpolation point number on the accuracy of Cholesky decomposition.
Based on the above parameter analysis, the simulation parameters selected in this example are presented in Table 1.
Table 1.
Simulation parameters.
4.1.2. Simulation Accuracy
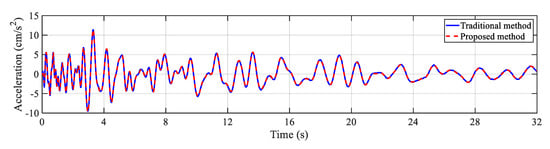
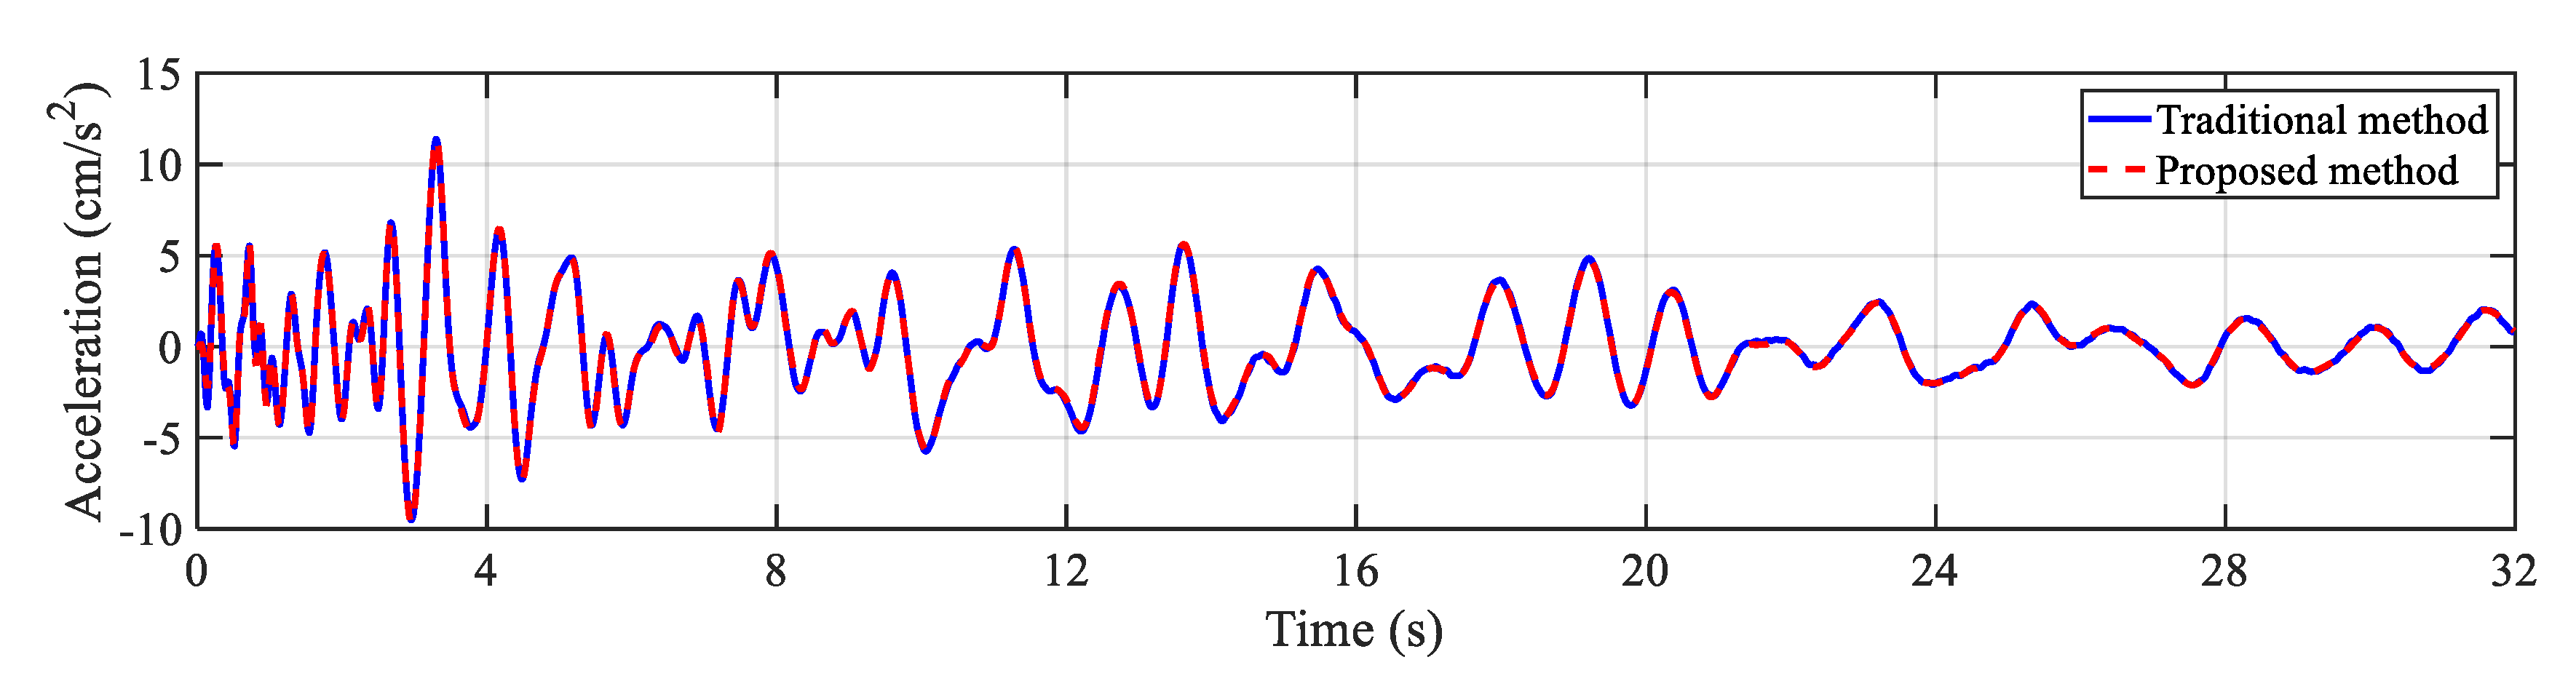
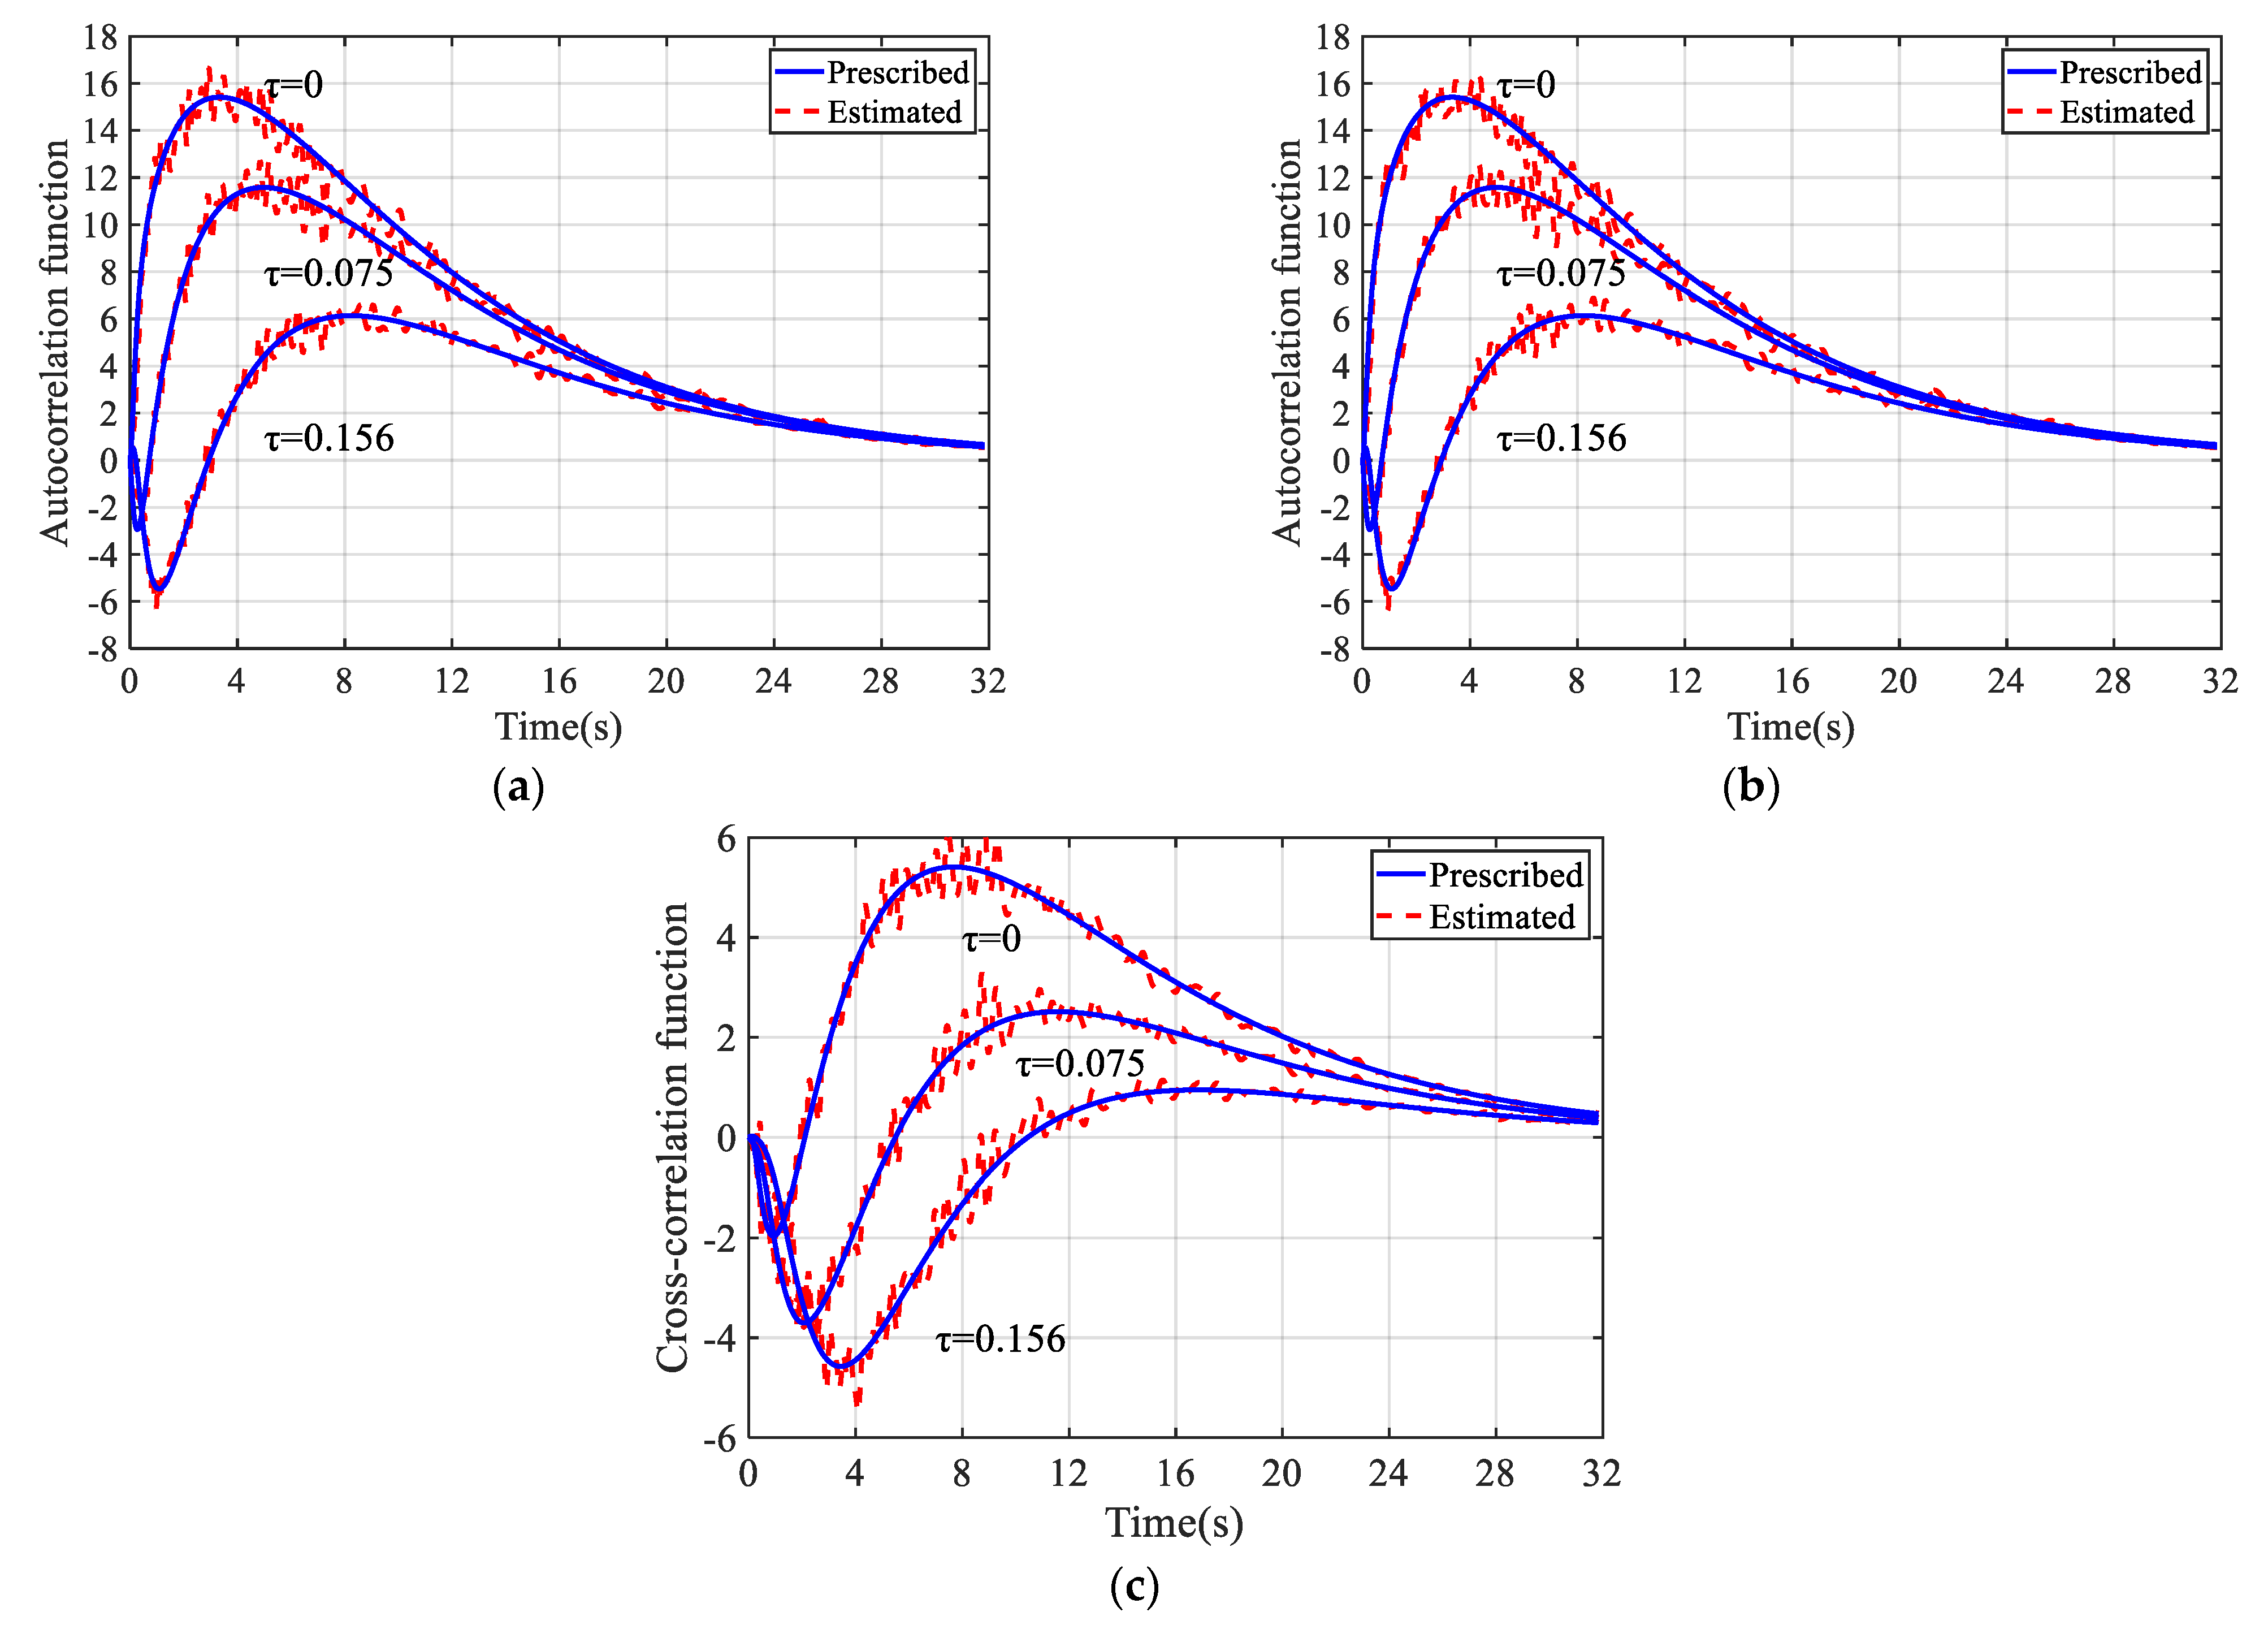
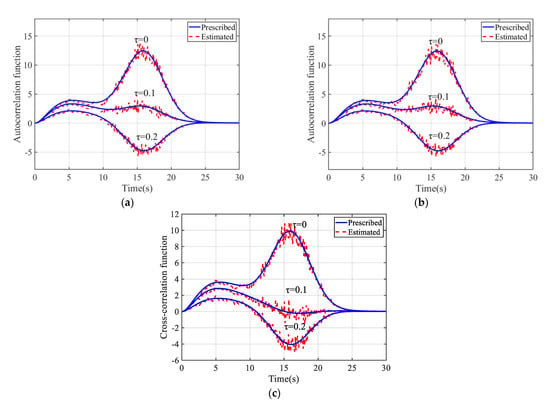
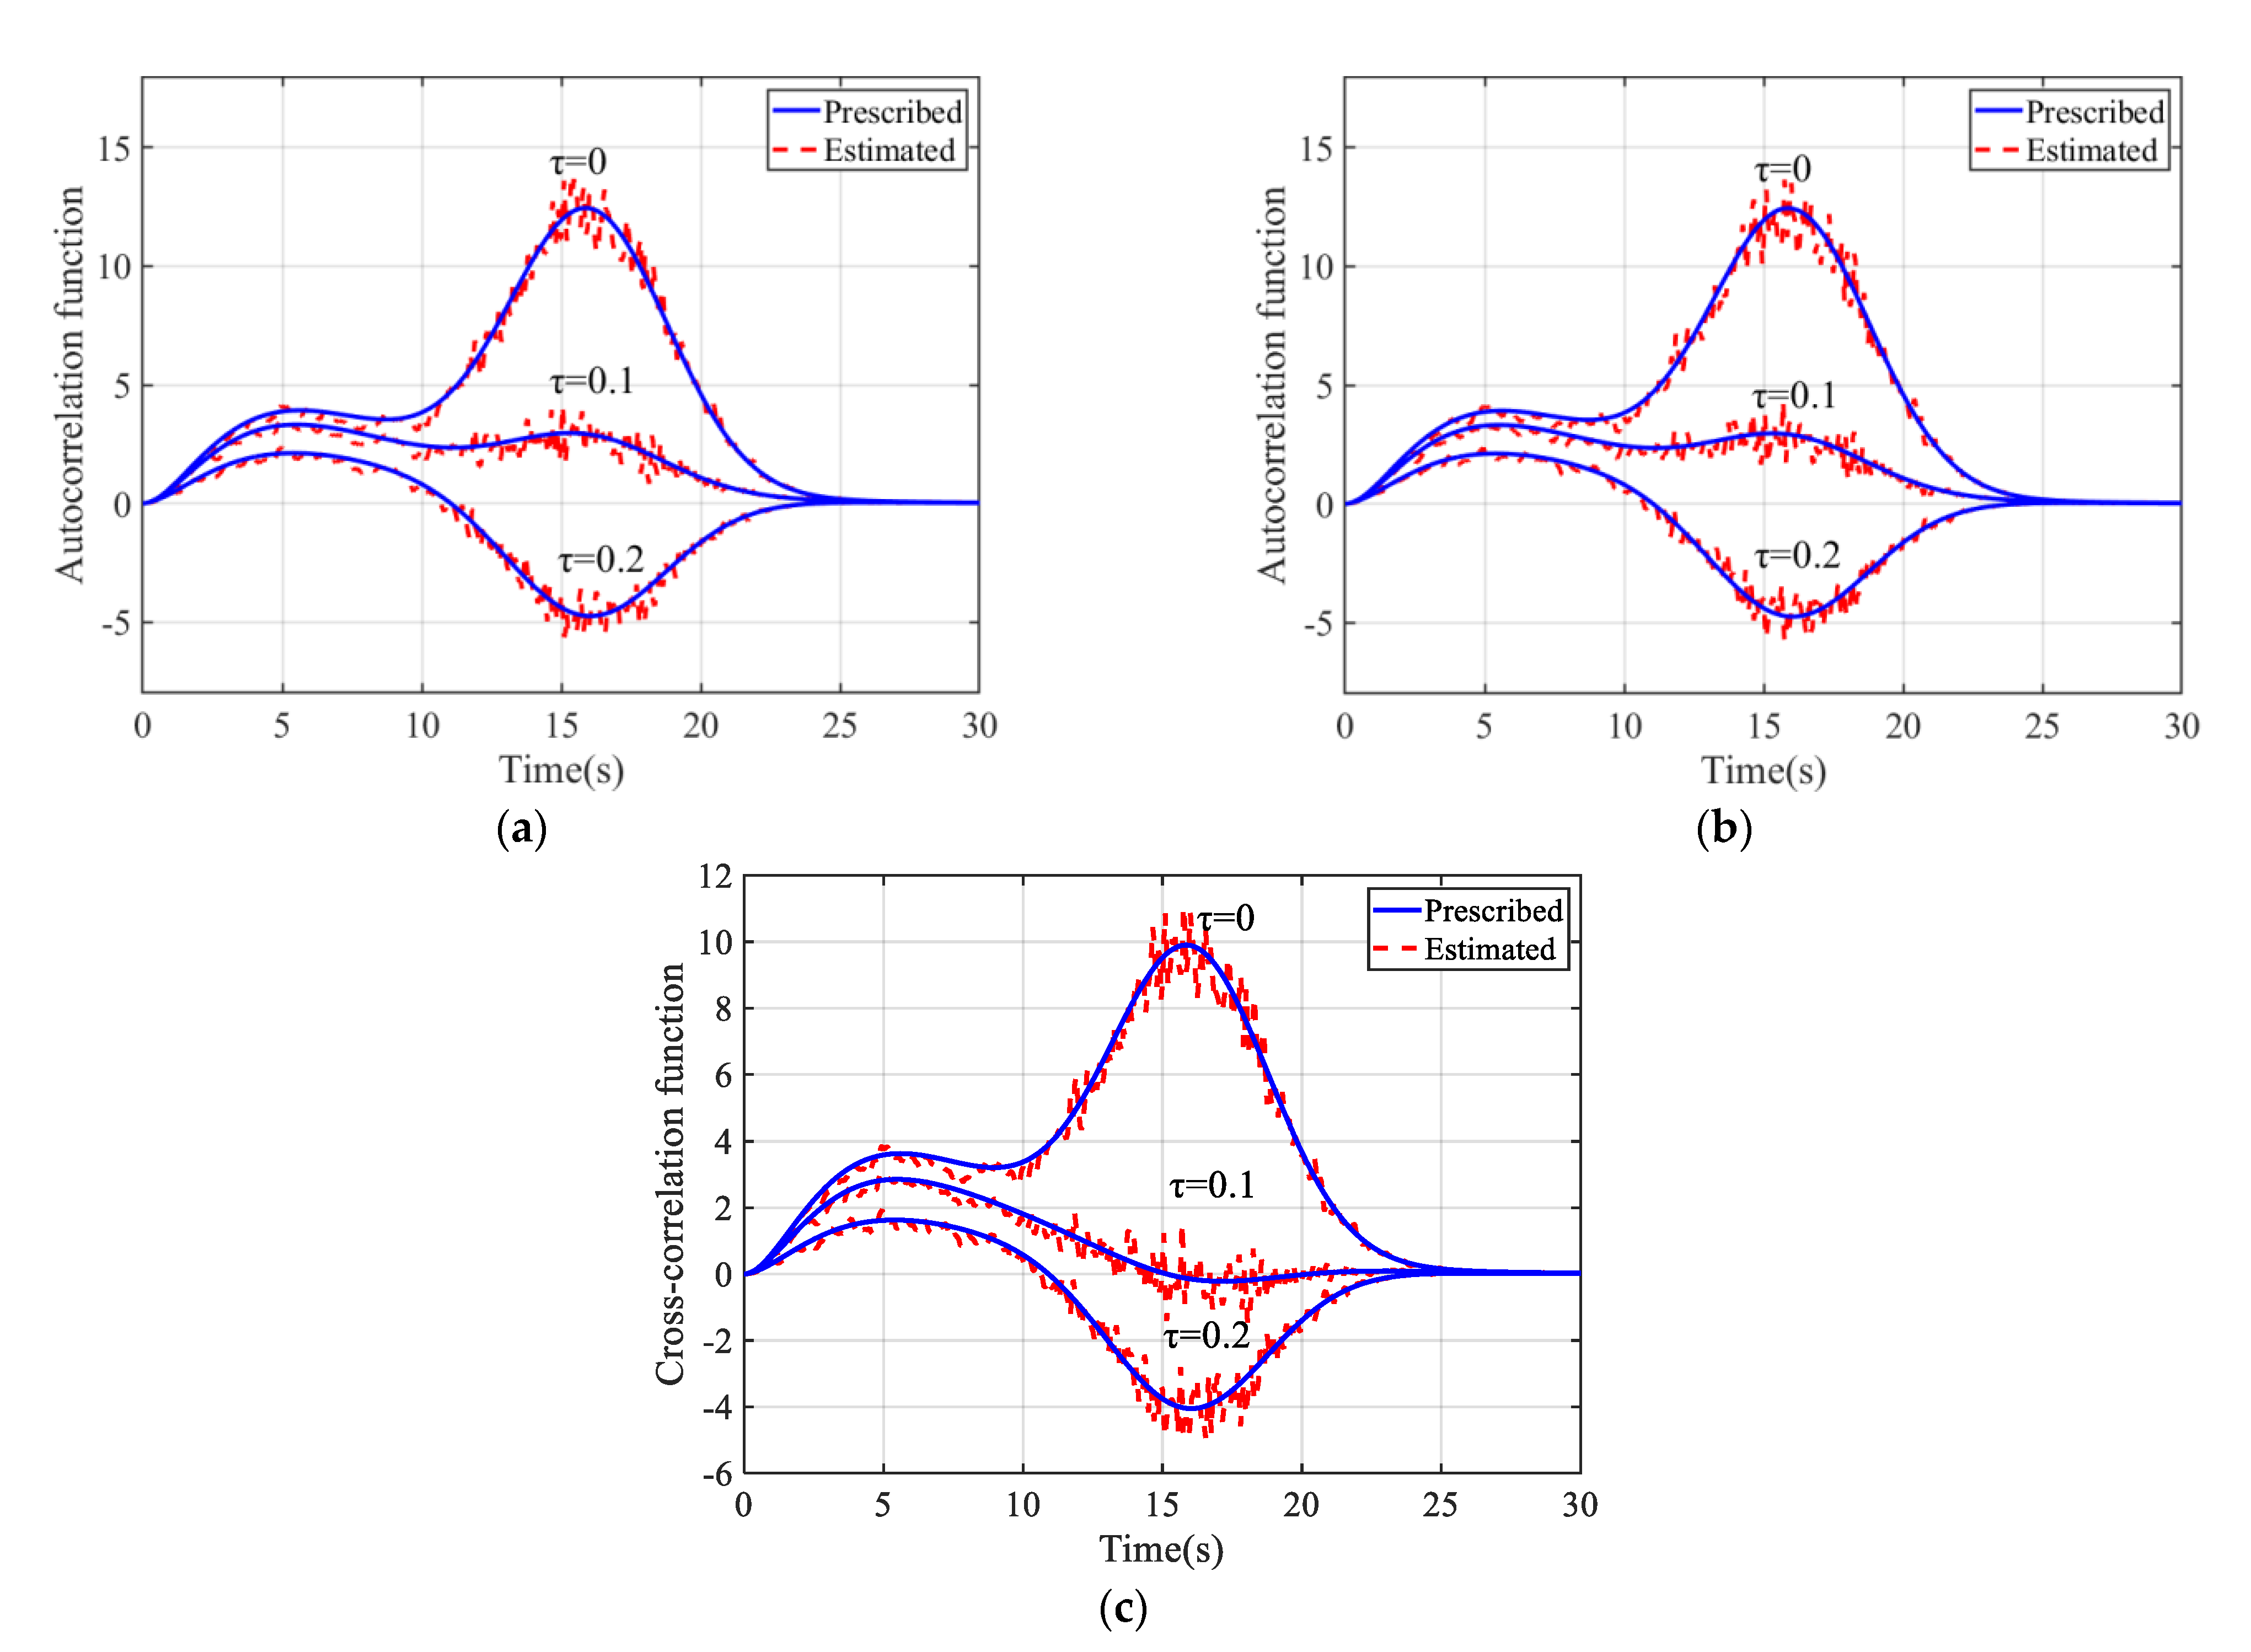
On the basis of the suggested method with the above simulation parameters, the nonstationary earthquake acceleration field was simulated. With a set of given phases , the acceleration sample at the first simulation point is shown in Figure 8, where the traditional exact method [4] was used for the comparison. Obviously, the two-sample time history curves overlapped almost exactly. To further test the efficacy of the simulated seismic acceleration field, the auto and cross-correlation functions were estimated by 1000 samples generated using the suggested approach. As a typical example, Figure 9 compares the estimated correlation functions and the corresponding target at points 1 and 20. It is clear that the suggested method was successful in simulating the nonstationary seismic acceleration field given by the nonseparable spectrum.
Figure 8.
Simulated nonstationary earthquake acceleration sample.
Figure 9.
Verification of correlation functions (1000 samples): (a) ; (b) ; (c) .
4.1.3. Simulation Efficiency
The suggested method used three accelerations to simulate nonstationary spatially varying seismic motions, including Cholesky decomposition, time-frequency decoupling and the FFT. To quantitatively study the simulation efficiency of the suggested method, the traditional efficient approximation method [21] was used for the comparison, where the traditional method adopted the FFT with the help of POD. Without loss of generality, it was assumed that the autospectrum of each simulation point was different. Table 2 displays the consumed time of two methods for 50, 100, 150 and 200 simulation points, where the ‘time ratio’ was the consumed time of the traditional method divided by that of the proposed method. Clearly, the suggested method was more efficient than the traditional method, and the simulation efficiency could be increased by more than tenfold. Furthermore, when the simulation points increased, the efficiency gains became more apparent.
Table 2.
Simulation efficiency comparison of two methods (1000 samples).
4.2. Nonuniformly Modulated Spectrum
In this section, it was assumed that the autospectrum of the above nonstationary earthquake acceleration field was replaced by the nonuniformly modulated power spectrum model [26], given by
where and are the modulation functions and given by
in which , , s and s, and are the stationary PSD functions determined by the one-sided Kanai–Tajimi spectrum, i.e.,
where ; ; the parameters and were, respectively, used for and . The coherence function was given by Equations (38)–(40).
The basic parameters used for the simulation were given as: the total time ; the cutoff frequency ; the time step ; and the frequency step . The POD interpolation parameters , and and the interpolation parameter for Cholesky decomposition are given in Table 1.
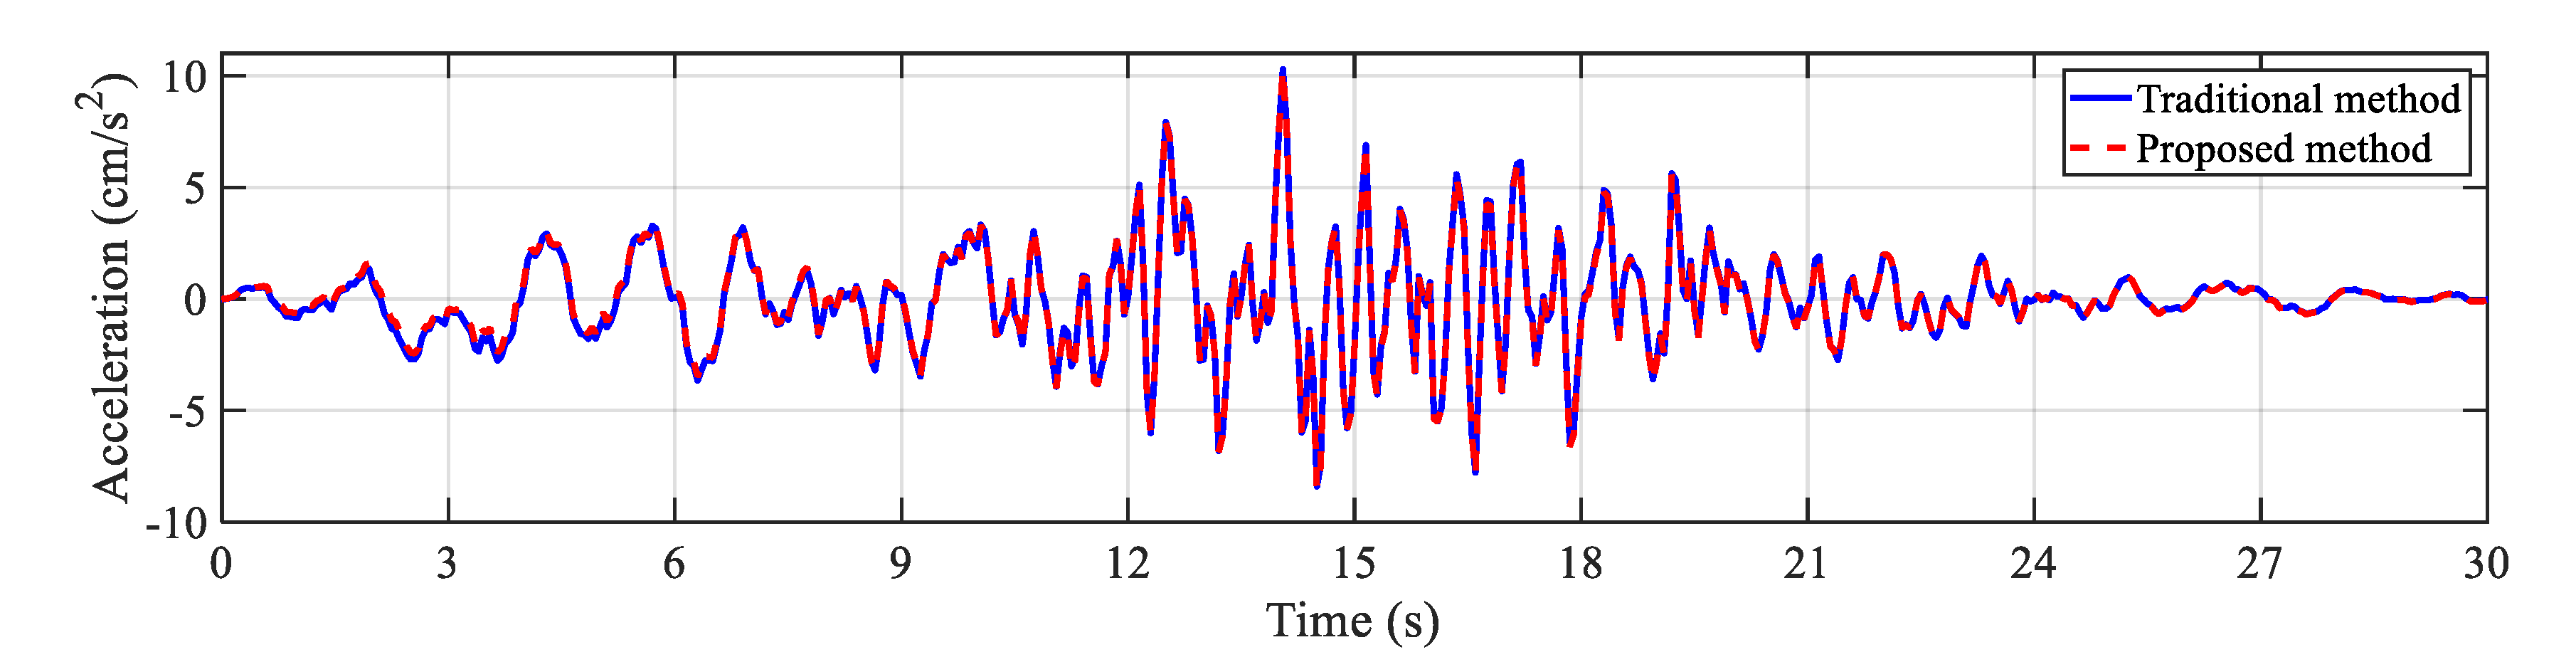
With a set of given phases , Figure 10 shows the simulated nonstationary earthquake acceleration time history of the first 30 s at the first simulation point. Further, 1000 earthquake acceleration samples were simulated to estimate the correlation function. The target correlation function could be calculated with Equation (7) based on the target spectrum and coherence function. As a typical example, Figure 11 compares the estimated correlation functions and the target at points one and five. Through the sample comparison and the correlation verification, the suggested method was also suitable for the nonstationary earthquake acceleration field described by the nonuniformly modulated EPSD.
Figure 10.
Simulated nonstationary earthquake acceleration sample.
Figure 11.
Verification of correlation functions (1000 samples): (a) ; (b) ; (c) .
5. Conclusions
Based on the spectral representation method, this paper proposed an effective interpolation approximation methodology for the simulation of spatially variable seismic motions. The interpolation technique was first utilized for the Cholesky decomposition of the lagged coherence matrix. Then, the POD interpolation technique was utilized for the decoupling of nonseparable EPSDs to achieve the usage of the FFT. Further, the simulation formula was optimized to reduce the number of FFT operations. The accuracy and efficiency of the proposed approach were examined via two numerical examples. Results showed that the error introduced by two steps of interpolations was fairly small and the simulation agreed with the targets very well. A few dozens of interpolation points could ensure that the error was within 1%. Furthermore, the efficiency generating sample functions were significantly enhanced. For example, for the nonstationary earthquake acceleration field with 100 simulation points, the simulation efficiency could be enhanced more than 13 times.
Author Contributions
Conceptualization, N.Z., L.P. and X.W.; methodology, N.Z. and X.W.; software, Z.X.; validation, X.L.; formal analysis, X.C. and X.W.; writing—original draft preparation, N.Z. and Z.X.; writing—review and editing, N.Z., X.L. and L.P.; supervision, N.Z. and X.W.; project administration, N.Z. and L.P. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by the National Natural Science Foundation of China (grant no. 52108464), the CRSRI Open Research Program (program SN: CKWV2019733/KY), the Dual Support Plan of Sichuan Agricultural University (grant no. 2021993510) and the Research Funding for Supporting the Postdoctoral Working in Chongqing (grant no. 2020LY06).
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
Not applicable.
Conflicts of Interest
The authors declare no conflict of interest.
Appendix A. Application of the FFT
To construct the discrete Fourier transform item in the simulation, Equation (36) can be rewritten as
where is given by
The time and frequency increments have the following relationship, i.e.,
Substituting Equation (A3) to Equation (A1), one had
Obviously, the FFT technique could be utilized for the summation with respect to in Equation (A4).
To avoid aliasing, the following requirement should be satisfied, i.e.,
Substituting Equation (A3) to Equation (A5), one had
References
- Kiureghian, A.D. A coherency model for spatially varying ground motions. Earthq. Eng. Struct. Dyn. 1996, 25, 99–111. [Google Scholar] [CrossRef]
- Zerva, A. Spatial Variation of Seismic Ground Motions: Modeling and Engineering Application; CRC Press: New York, NY, USA, 2009. [Google Scholar]
- Hao, H.; Oliveira, C.S.; Penzien, J. Multiple-station ground motion processing and simulation based on SMART-1 array data. Nucl. Eng. Des. 1989, 111, 293–310. [Google Scholar] [CrossRef] [Scilit]
- Deodatis, G. Non-stationary stochastic vector processes: Seismic ground motion applications. Probabilistic Eng. Mech. 1996, 11, 149–167. [Google Scholar] [CrossRef] [Scilit]
- Cacciola, P.; Deodatis, G. A method for generating fully non-stationary and spectrum-compatiable ground motion vector processes. Soil Dyn. Earthq. Eng. 2011, 31, 351–360. [Google Scholar] [CrossRef] [Scilit]
- Wu, Y.; Gao, Y.; Li, D. Simulation of spatially correlated earthquake ground motions for engineering purposes. Earthq. Eng. Eng. Vib. 2011, 10, 163–173. [Google Scholar] [CrossRef] [Scilit]
- Bi, K.; Hao, H. Modelling and simulation of spatially correlated earthquake ground motions at sites with varying conditions. Prob. Eng. Mech. 2012, 29, 92–104. [Google Scholar] [CrossRef] [Scilit]
- Yang, W.W.; Chang, T.Y.P.; Chang, C.C. An efficient wind field simulation technique for bridges. J. Wind. Eng. Ind. Aerodyn. 1997, 67, 697–708. [Google Scholar] [CrossRef] [Scilit]
- Cao, Y.; Xiang, H.; Zhou, Y. Simulation of stochastic wind velocity field on long-span bridges. J. Eng. Mech. 2000, 126, 1–6. [Google Scholar] [CrossRef] [Scilit]
- Zhao, N.; Huang, G. Wind velocity field simulation based on enhanced closed-form solution of Cholesky decomposition. J. Eng. Mech. 2020, 146, 04019128. [Google Scholar] [CrossRef] [Scilit]
- Gao, Y.; Wu, Y.; Li, D.; Liu, H.; Zhang, N. An improved approximation for the spectral representation method in the simulation of spatially varying ground motions. Prob. Eng. Mech. 2012, 29, 7–15. [Google Scholar] [CrossRef] [Scilit]
- Huang, G.; Liao, H.; Li, M. New Formulation of Cholesky Decomposition and Applications in Stochastic Simulation. Prob. Eng. Mech. 2013, 34, 40–47. [Google Scholar] [CrossRef] [Scilit]
- Jiang, Y.; Zhao, N.; Peng, L.; Zhao, L.; Liu, M. Simulation of stationary wind field based on adaptive interpolation-enhanced scheme. J. Wind. Eng. Ind. Aerodyn. 2019, 195, 104001. [Google Scholar] [CrossRef] [Scilit]
- Zhao, N.; Jiang, Y.; Peng, L.; Chen, X. Fast simulation of nonstationary wind velocity fields by proper orthogonal decomposition interpolation. J. Wind. Eng. Ind. Aerodyn. 2021, 219, 104798. [Google Scholar] [CrossRef] [Scilit]
- Jiang, Y.; Zhao, N.; Peng, L.; Xin, J.; Liu, S. Fast simulation of fully non-stationary wind fields using a new matrix factorization assisted interpolation. Mech. Syst. Sig. Process. 2022, 172, 108973. [Google Scholar] [CrossRef] [Scilit]
- Yang, J.N. Simulation of random envelope processes. J. Sound Vib. 1972, 21, 73–85. [Google Scholar] [CrossRef] [Scilit]
- Wittig, L.E.; Sinha, A.K. Simulation of multicorrelated random processes using the FFT algorithm. J. Acoust. Soc. Am. 1975, 58, 630–634. [Google Scholar] [CrossRef] [Scilit]
- Spanos, P.D.; Kougioumtzoglou, I.A. Harmonic wavelets based statistical linearization for response evolutionary power spectrum determination. Prob. Eng. Mech. 2012, 27, 57–68. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Kareem, A. Simulation of multivariate nonstationary random processes: Hybrid DFT and digital filtering approach. J. Eng. Mech. 1997, 123, 1302–1310. [Google Scholar] [CrossRef] [Scilit]
- Huang, G. An efficient simulation approach for multivariate nonstationary process: Hybrid of wavelet and spectral representation method. Prob. Eng. Mech. 2014, 37, 74–83. [Google Scholar] [CrossRef] [Scilit]
- Huang, G. Application of Proper Orthogonal Decomposition in Fast Fourier Transform—Assisted Multivariate Nonstationary Process Simulation. J. Eng. Mech. 2015, 141, 04015015. [Google Scholar] [CrossRef] [Scilit]
- Liu, Z.; Liu, Z.; Ruan, X.; Zhang, Q. Spectral representation-based dimension reduction for simulating multivariate non-stationary ground motions. Soil Dyn. Earthq. Eng. 2018, 114, 313–325. [Google Scholar] [CrossRef] [Scilit]
- Ruan, X.; Liu, Z.; Liu, Z.; Fan, Y. Dimension-reduction representation of stochastic ground motion fields based on wavenumber-frequency spectrum for engineering purposes. Soil Dyn. Earthq. Eng. 2021, 143, 106604. [Google Scholar] [CrossRef] [Scilit]
- Priestley, M.B. Evolutionary spectra and non-stationary processes. J. R. Stat. Soc. Ser. B 1965, 27, 204–229. [Google Scholar] [CrossRef] [Scilit]
- Conte, J.P.; Peng, B.F. Fully nonstationary analytical earthquake ground-motion model. J. Eng. Mech. 1997, 123, 15–24. [Google Scholar] [CrossRef] [Scilit]
- Li, Y.; Kareem, A. Simulation of multivariate nonstationary random processes by FFT. J. Eng. Mech. 1991, 117, 1037–1058. [Google Scholar] [CrossRef] [Scilit]
- Konakli, K.; Kiureghian, A.D. Simulation of spatially varying ground motions including incoherence, wave-passage and differential site-response effects. Earthq. Eng. Struct. Dyn. 2012, 41, 495–513. [Google Scholar] [CrossRef] [Scilit]
- Zhao, N.; Huang, G. Fast simulation of multivariate nonstationary process and its application to extreme winds. J. Wind. Eng. Ind. Aerodyn. 2017, 170, 118–127. [Google Scholar] [CrossRef] [Scilit]
- Wang, H.; Xu, Z.; Feng, D.; Tao, T. Non-stationary turbulent wind field simulation of bridge deck using non-negative matrix factorization. J. Wind. Eng. Ind. Aerodyn. 2019, 188, 235–246. [Google Scholar] [CrossRef] [Scilit]
- Harichandran, R.S.; Vanmarcke, E.H. Stochastic variation of earthquake ground motion in space and time. J. Eng. Mech. 1986, 112, 154–174. [Google Scholar] [CrossRef] [Scilit]
- Li, B.; Peng, L.; Jiang, Y.; Wu, F.; Hui, Y.; Luo, Y. Simulation of stationary non-Gaussian stochastic vector processes using an eigenvalue-based iterative translation approximation method. Mech. Syst. Sig. Process. 2022, 175, 109128. [Google Scholar] [CrossRef] [Scilit]

Publisher’s Note: MDPI stays neutral with regard to jurisdictional claims in published maps and institutional affiliations. |
© 2022 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (https://creativecommons.org/licenses/by/4.0/).