


Abstract
This paper investigates the stability of telehandlers operating on inclined terrain through a sequential methodological approach. In a first stage, stability is assessed using quasi-static methods based on force and moment equilibrium, including the load transfer matrix and the stability pyramid. These approaches account for gravitational and inertial effects through equivalent external forces and moments applied at the global centre of gravity, enabling efficient evaluation of load redistribution and proximity to rollover thresholds under generalized quasi-static conditions. The application of these methods highlights intrinsic limitations when addressing structurally complex machines such as telehandlers equipped with a pivoting rear axle and evolving mass distribution due to boom motion. In particular, quasi-static approaches require a priori assumptions regarding the effective rollover axis and cannot fully capture the coupled geometric and contact interactions between rear axle articulation limits, centre of gravity migration, tyre–ground interface behaviour, and support polygon evolution. To overcome these limitations, a nonlinear dynamic multibody model based on the three-dimensional Bond Graph (3D Bond Graph) methodology is introduced. The model is implemented within a virtual tilt–rotation test platform and validated against experimental results obtained from ISO 22915-14 stability tests. The comparison confirms compliance with normative requirements and demonstrates that the dynamic framework captures condition-dependent rollover mechanisms and transitions between distinct virtual rollover axes that cannot be fully explained by quasi-static formulations. Unlike most previous studies, which focus on fixed configurations or forward-driving scenarios, the proposed framework analyzes stability evolution under spatial inclination while accounting for structural articulation constraints. The explicit identification of rollover axis transitions induced by rear axle articulation provides a deeper mechanistic interpretation of telehandler stability and supports the use of high-fidelity dynamic simulation as a complementary tool for test interpretation, experimental planning, and the development of predictive stability and operator assistance systems.
1. Introduction
Stability is a critical aspect in the design and safe operation of off-road machinery. In mechanical terms, stability refers to the ability of a vehicle to maintain equilibrium under external disturbances, preventing loss of ground contact or uncontrolled tipping. For load-handling machines operating on uneven terrain, stability is influenced by the position of the centre of gravity (CG), load configuration, terrain inclination, and the mechanical architecture of the chassis and suspension systems.
Telehandlers present particular challenges in this regard. By combining the functionalities of forklifts, cranes, and loaders within a single mobile platform, telehandlers operate with elevated and horizontally extended loads while maintaining off-road mobility. This versatility enables operation in construction, agriculture, and material handling sectors, but also increases exposure to instability scenarios—especially during boom extension, load transport on slopes, or maneuvers performed under combined inclination conditions.
From a theoretical perspective, stability can be interpreted through two complementary approaches: (i) The mechanical approach, based on the equilibrium of forces and moments, and (ii) The geometric approach, which uses the projection of the CG relative to key spatial limits as an indicator of balance. This duality has been highlighted by Biestrato, who emphasizes the equivalence between force-based and purely geometric formulations—particularly under quasi-static conditions—when assessing proximity to tip-over thresholds [1].
Regulatory frameworks and load charts are primarily based on such simplified assumptions, which are well-suited for stationary lifting configurations. However, telehandlers are increasingly employed in dynamic operating conditions, including load transport over uneven terrain, turning under load, or operation on inclined surfaces. Under these circumstances, transient inertial effects, tire compliance, and rear axle articulation may significantly influence rollover behavior.
Although the stability of other off-road vehicles—particularly agricultural tractors—has been extensively studied, peer-reviewed research specifically addressing the structural mechanisms governing telehandler rollover remains comparatively limited. In particular, the interaction between three-dimensional inclination, rear axle oscillation, and load transfer evolution under standardized testing configurations has not been comprehensively investigated.
The present study aims to analyze telehandler stability from a mechanistic perspective through a sequential methodological approach. First, generalized quasi-static theoretical tools are formulated and applied. Subsequently, in light of their inherent limitations when addressing structurally articulated systems, a detailed nonlinear dynamic multibody model is introduced to provide a physically consistent interpretation of the observed behavior. The work builds upon a previously developed three-dimensional bond graph (3D Bond Graph) virtual model of a telehandler done by Puras et al., 2024 [2], extending it through integration with a Virtual Tilt–Rotary Test Platform capable of reproducing controlled elevation and rotation conditions representative of ISO 22915-14 [3] configurations. The complete model is experimentally supported by full-scale tests performed on a dedicated tilting platform developed in collaboration with the Spanish manufacturer AUSA. Figure 1 shows the tilting platform on the telehandler is 138 tested and the BG-3D virtual model used.
Figure 1.
(a) Telescopic machine on Tilting Platform, Source: AUSA (AUSA S.L., Castelladral 1, 08243 Manresa, Barcelona, Spain) (b) Virtual BG-3D Model (20-Sim animation tool 20-Sim 5.0) of Telescopic machine on tilting virtual Platform in a horizontal position.
Rather than focusing solely on model validation—which was addressed in prior work—the objective of this study is to deepen understanding of rollover mechanisms under inclined configurations and to interpret the evolution of load transfer and centre of gravity migration up to the critical tipping threshold. The high-fidelity simulations, supported by experimental measurements, provide insight into the physical processes governing instability and establish a foundation for future development of reduced-order predictive tools and advanced stability assistance systems.
The remainder of this paper is organized as follows. Section 2 presents a structured review of existing stability assessment approaches, current research on telehandlers, and prevailing industrial practices. Section 3 introduces the theoretical foundations applied in this study, including the stability pyramid concept, load transfer matrix formulation, and the analytical implications of rear axle non-collinearity. Section 4 describes the modelling of the telehandler and the Virtual Tilt–Rotary Test Platform using the 3D Bond Graph methodology. Section 5 details the experimental framework and testing procedures, while Section 6 presents the comparative analysis of numerical and experimental results.
2. A Brief Literature Review, Focusing on Recent Advances in Stability Analysis of Off-Road Machinery
2.1. Stability Assessment Approaches in Mobile Machinery
The stability of mobile machinery is a decisive factor for both regulatory compliance and operational safety. Stability assessment methods can be broadly classified into two main categories: model-based approaches and experimental approaches, each serving different objectives and requiring distinct levels of input data [4].
From a modelling perspective, three levels of representation are commonly distinguished according to complexity and intended application:
- (i)
- Kinematic models, based exclusively on geometric relationships and their evolution over time. These models use parameters such as centre of gravity (CG) position, wheelbase, and boom geometry. They are computationally efficient and suitable for preliminary design assessments, but do not account for force interactions or inertial effects.
- (ii)
- Quasi-static models, which incorporate force and moment equilibrium, sometimes including simplified tire compliance, while neglecting inertial contributions. These approaches are particularly appropriate for low-speed operations, steady slopes, and static certification procedures.
- (iii)
- Dynamic multibody models, which include inertial effects, transient loads, and interaction with irregular terrain. These models are implemented either in commercial multibody software (e.g., MSC Adams, RecurDyn) or through custom solvers, and are especially relevant for analysing rollover dynamics, transient manoeuvres, and the development of control strategies [5,6,7,8,9,10,11].
Experimental approaches complement modelling by directly capturing real-world phenomena that are difficult to represent numerically, such as tire deformation, ground compliance, structural flexibility, and operator variability. These methods are primarily used for regulatory compliance, model validation, and system calibration, following standards such as ISO 16231 [12,13], ISO 789-6 [14], and ISO 22915-14 [3]. Typical procedures include CG determination techniques and tilt-platform rollover tests under controlled boundary conditions.
In practice, modelling and experimentation are inherently complementary. Numerical models provide predictive flexibility and allow extensive parametric analysis, whereas experimental testing supplies validation data and ensures regulatory conformity. Robust stability assessment frameworks, therefore, integrate both approaches, using experimental data to calibrate models and models to design efficient and safe experimental campaigns.
2.2. Technological Advances in Tractors as a Reference
Off-road vehicles face significant operational challenges due to the unstructured nature of their working environments. Among these, rollover risk is a critical factor, especially under high load conditions, steep slopes, or uneven surfaces. Agricultural tractors have led the development of technological solutions aimed at improving stability, becoming a key reference for other off-road vehicles such as telehandlers. In recent years, tractors have incorporated advanced perception systems and intelligent control algorithms to detect and anticipate instability conditions. Inertial sensors, GPS, LiDAR, and predictive models have enabled accurate estimation of variables such as rollover angle, centre of gravity, or lateral load transfer ratio (LTR), resulting in early warning systems and active posture control. Adaptive control strategies coordinating steering, suspension, and braking have been developed with positive outcomes in both simulations and real environments. These technologies have been combined with hybrid modelling approaches (physics-based and data-driven) and machine learning techniques to enhance responsiveness and robustness in changing environments. The use of electronic platforms and distributed computing is also being explored to enable real-time stability decision-making.
2.3. Current State of Stability in Telehandlers
Despite the increasing adoption of telehandlers in construction and agriculture, peer-reviewed studies explicitly focused on their stability remain relatively scarce, suggesting either a genuine research gap or that much of the know-how is retained as proprietary within the industry. The available literature can be broadly grouped into two domains: (i) works centred on hydraulic architectures, hybrid powertrains, and energy management—where stability is a secondary or implicit consideration (e.g., [15,16,17,18,19,20,21])—and (ii) investigations explicitly addressing stability.
Stability evaluation in telehandlers typically relies on theoretical and simulation-based approaches adapted from other off-road vehicles, encompassing static, quasi-static, and dynamic analyses, each with distinctive applications and constraints. These methods differ in complexity and in how accurately they reproduce real operating conditions. For example [22], in collaboration with the FIAT group, developed a parametric multibody model in Altair MotionSolve to validate tipping limits and load distribution against quasi-static experimental tests. Building on more advanced modelling [23], an ADAMS multibody model was implemented that incorporated tyre stiffness and damping to estimate critical overturning and sliding thresholds, showing closer agreement with experimental platform tests than static models that treat tyres as rigid. Nevertheless, most such models omit hydraulic actuation systems and simplify complex terrain interactions.
Other approaches focus on static or kinematic estimation of the centre of gravity (CG), sometimes aiming for real-time onboard monitoring [24]. For instance, a simplified kinematic model was proposed, implemented in MATLAB to determine the CG position with an error below 10 mm across tool configurations, reducing computational load for onboard control. These models achieve high precision under controlled conditions but neglect transient dynamics, tyre–ground compliance effects, and terrain irregularities. Dynamic methodologies, though less common, have demonstrated their potential to predict instability with greater fidelity.
A smaller body of work integrates experimental telemetry directly into stability assessment [25], in collaboration with the Merlo Group, exemplifies this by reconstructing machine motion in 3D animations from logged CAN and IMU data, enabling both post-incident analysis and refinement of stability control laws.
In summary, although methodologies applied to telehandlers mirror those used for other off-road vehicles, current research remains fragmented—either static/kinematic CG estimation, quasi-static validation against standards, or dynamic modelling with partial system integration. The comprehensive integration of fully dynamic simulation, realistic hydraulic actuation, detailed tyre–ground interaction modelling, and open experimental validation is still largely absent, representing a significant opportunity for advancement.
2.4. Summary of Vehicle Stability Metrics and Trends with Focus on Telehandlers
Vehicle stability assessment relies on quantitative indices that relate geometric configuration, load distribution, and dynamic response to rollover risk. These metrics range from purely static geometric factors to dynamic indicators incorporating vehicle motion variables. A classical static parameter is the Static Stability Factor (SSF), defined as:
where is the average track width and is the height of the centre of gravity (CG). Higher SSF values indicate greater resistance to lateral rollover. Although widely used in regulatory contexts (e.g., NHTSA [26]), SSF reflects purely static conditions and does not account for transient effects such as steering input, load shifts, or terrain irregularities.
To address load redistribution effects, the Lateral Load Transfer Ratio (LTR) is commonly adopted. It is defined as:
where RFR, RRR, RFL, RRL represent the vertical reaction forces at each wheel. LTR ranges from −1 to 1; values approaching ±1 indicate loss of contact on one side and imminent lateral rollover. Because it directly reflects wheel load imbalance, LTR is widely used in rollover warning systems and can be derived from load transfer formulations such as the transfer matrix approach described in Section 3.
For machines exposed to longitudinal instability, such as telehandlers during braking or boom extension, a Longitudinal Load Transfer Ratio (LLTR) can be defined analogously to quantify front–rear load imbalance:
While LTR and LLTR are effective quasi-static indicators, they do not explicitly incorporate vehicle rotational dynamics. To introduce dynamic effects [27], proposed the Stability Index (SI), defined as:
where is the roll angle and cri is roll rate, normalized with respect to critical threshold values. SI combines attitude and angular velocity to estimate proximity to rollover, providing a more proactive measure of instability.
Recent research trends aim to enhance these indices using sensor fusion and machine learning techniques to estimate roll state and load transfer in real time [28]. However, in telehandlers, practical implementation remains limited. Direct measurement of wheel reactions is uncommon due to sensor cost and integration complexity, and most commercial systems rely on static load charts combined with threshold-based logic.
As a result, although several stability metrics are available, their application in telehandlers is typically restricted to quasi-static or reactive strategies. The development of physically grounded dynamic models capable of reproducing load transfer and rollover mechanisms under standardized test configurations (e.g., ISO 22915-14) represents a necessary intermediate step toward predictive and model-based stability control architectures.
2.5. Industrial Context and Current Stability Control Framework in Telehandlers
Current stability systems in telehandlers are predominantly reactive and primarily designed to ensure compliance with standards such as EN 15000 [29]. These systems typically monitor boom position, handled load, and axle load distribution, activating visual or acoustic warnings, progressively reducing hydraulic speed, or blocking movements when predefined limits derived from static load charts are reached.
Although recent developments have introduced proportional control strategies, multi-axis sensing, and segmented risk zones, most commercial solutions still rely on quasi-static stability margins. The physical mechanisms governing rollover—particularly under combined inclination conditions or when rear-axle oscillation reaches its mechanical limits—are not explicitly modelled.
In other off-road machinery sectors, more advanced approaches based on dynamic load transfer estimation and predictive control have been investigated. However, their direct implementation in telehandlers remains limited due to economic constraints, regulatory frameworks, and the specific architectural characteristics of these machines, notably the oscillating rear axle. In this context, the development and experimental validation of a physically grounded dynamic model capable of reproducing rollover behaviour under standardized configurations (e.g., ISO 22915-14) constitutes a necessary intermediate step between current static-based reactive systems and future predictive, model-based stability control architectures.
The present work, therefore, focuses on the experimental validation and mechanistic interpretation of rollover phenomena using the previously developed BG3D dynamic model, providing the physical foundation required for subsequent advances in predictive assistance or control-oriented applications.
2.6. Research Gap and Contributions
Building upon the limitations identified in the scientific literature and current industrial practice, a key question remains insufficiently addressed: What structural mechanism governs telehandler rollover under inclined ISO 22915-14 configurations, and how does this mechanism evolve up to the critical tipping threshold?
Existing studies typically focus on quasi-static compliance verification, reduced-order dynamic models for control calibration, or kinematic centre-of-gravity estimation. However, the comprehensive integration of three-dimensional multibody dynamics, explicit hydraulic actuation, tyre–ground compliance, and experimental validation under combined inclination conditions remains largely unexplored. In particular, the evolution of the virtual rollover axis in the presence of rear axle articulation has not been systematically investigated.
To address this gap, the present study builds upon a previously developed and experimentally validated BG3D virtual model [2], extending its application to inclined configurations representative of ISO 22915-14 testing scenarios. The model is formulated as a spatial multibody system with explicit hydraulic and tyre–ground interaction modelling, and is validated using a dedicated two-degree-of-freedom tilting platform enabling controlled elevation–rotation conditions.
The main contributions of this work are:
- -
- Mechanistic reformulation of telehandler rollover as the evolution of a spatial system defined by the interaction between centre-of-gravity migration and a variable virtual rollover axis under inclined configurations.
- -
- Extension of quasi-static stability analysis through explicit consideration of three-dimensional inclination (α–β), rear axle oscillation, and functional inertial effects associated with boom motion and load handling.
- -
- Identification of statically indeterminate (hyperstatic) conditions arising from non-colinearity between the rear axle pivot axis and the emergent rollover axis during instability progression.
- -
- Development and experimental validation of a multidomain BG3D dynamic model, integrating hydraulic actuation, tyre compliance, and full spatial multibody representation under ISO 22915-14 inclined test conditions.
Together, these contributions provide a physically grounded basis for improved interpretation of rollover mechanisms and establish a foundation for future predictive stability and control-oriented developments in telehandlers.
3. Fundamental Concepts Related to Stability
The stability of a telehandler is a critical aspect for ensuring both operational safety and the reliability of its control systems. The complex interaction among load distribution, inertial effects, vehicle geometry, and ground conditions requires a quantitative framework capable of assessing rollover risk under operating configurations.
This chapter introduces three fundamental concepts that together provide a comprehensive view of the machine’s static stability behaviour.
The first two—the Stability Pyramid and the Load Transfer Matrix—correspond to conventional analytical methodologies typically used to estimate stability margins. The third—the Rear Axle Movement Mechanism—is an original interpretative model proposed by the authors to bridge the gap between theoretical predictions and real behaviour.
Stability Pyramid, a geometric–analytical model that relates the resultant force vector to the spatial stability boundaries, enabling the estimation of rollover risk in both lateral and longitudinal directions.
Load Transfer Matrix, which allows the calculation of reaction forces at the vehicle’s support points from the external forces and moments applied at the centre of gravity. In this work, the formulation is extended to represent the machine operating on an inclined surface, emulated by a platform tilted at a given elevation angle, allowing the analysis of load redistribution as the vehicle changes its heading on the slope.
Although these two methodologies are commonly applied in a simplified form, they are here reformulated within a generalized analytical framework, as detailed in the following subsections. This approach provides a more rigorous understanding of load transfer phenomena, but it also highlights discrepancies between theoretical models and experimental observations—particularly regarding the load distribution on the rear oscillating axle, often assumed to be symmetrical between the two rear wheels.
To address these inconsistencies, the third subsection presents a new vector-based interpretation of the rear axle movement mechanism, which accounts for the non-collinearity between the pivot axis and the virtual rollover axis of the front chassis (V1) and its effect on vehicle stability. The validity of this interpretation will be further examined and corroborated in Section 6 through the comparison between virtual simulations and experimental data.
3.1. Stability Pyramid
3.1.1. Geometric Definition of the Stability Pyramid
When discussing vehicle stability, we are essentially evaluating whether the normal reactions (wheel-ground contact forces) remain positive and sufficient to sustain the system under all acting loads, including weight, inertia, and external moments. A rollover instability occurs when a vehicle, normally maintained in an upright position, undergoes a rotation that reduces the number of ground contact points until the remaining ones lie along a single line—known as the rollover axis. At this critical condition, mobility control is lost, and unless the situation is reversed, the vehicle will ultimately tip over.
The stability pyramid is a virtual three-dimensional volume representing the spatial region within which the resultant force acting on the vehicle’s global centre of mass (CM) must remain to ensure both static and dynamic stability [30]. The construction of this pyramid is based on the wheel–ground contact points and the vehicle’s global centre of mass. The stability pyramid is defined by:
- (i)
- Support Base Polygon
The support base is a convex polygon formed by projecting onto the horizontal plane only the outermost wheel–ground contact points that define the vehicle’s support perimeter. These points are referred to as ground contact points and are indexed following a clockwise convention as viewed from above.
This definition applies to a wide range of telehandler configurations, from conventional models with a rear oscillating axle—where the effective support base may reduce to a triangle formed by the two front wheels and the rear axle pivot point—to configurations equipped with extendable stabilizers that actively enlarge the support base. It also encompasses articulated platforms, in which the position of the support points varies dynamically according to the articulation angle.
- (ii)
- Lateral Faces
The lateral faces of the stability pyramid are defined by planes connecting the centre of mass with each pair of consecutive ground contact points. Each of these planes can be constructed from two vectors: one extending from to , and the other either from or, alternatively, connecting the two consecutive ground points, i.e., (see Figure 2). These planes generate triangular surfaces forming the lateral faces of the pyramid. The pyramid extends from the convex support polygon at its base to its apex located at the vehicle’s centre of mass. It is important to note that the intersection of these surfaces with the actual terrain—which may be irregular and not necessarily flat or horizontal—defines the effective footprint of the stability pyramid.
Figure 2.
Schematic representation of the stability pyramid.
- (iii)
- Apex: The apex of the stability pyramid coincides with the vehicle’s centre of mass, which serves as the upper vertex of this three-dimensional figure. It is also the point where the resultant forces and moments determining system stability are applied.
3.1.2. Analytical Description of the Lateral Faces, Rollover Axes, Equivalent Force, and Angular Metric of Instantaneous Stability
Each lateral face of the pyramid is defined by a triangle connecting two consecutive ground contact points, and , and the vehicle’s centre of mass, . This triangle forms an inclined plane whose orientation defines a potential instantaneous rollover axis.
The axis itself is represented by the base vector ai:
While a second vector , orthogonal to the axis and originating at the centre of mass, lies in the same plane and serves as a reference direction for evaluating the direction of the net load relative to that face.
The external loading acting on the vehicle is the sum of gravitational and inertial effects and is modelled as a net force vector and a net moment vector , both applied at the centre of mass. For each rollover axis , the component of that is perpendicular to the axis is obtained by removing its projection onto , that is:
This perpendicular component is the portion of the force that may contribute to rotation about the edge defined by .
In parallel, the moment component that is aligned with the axis is computed as:
which is the only portion of the moment vector that effectively contributes to a potential tipping motion about the axis.
To simplify analysis, the moment is replaced by an equivalent force couple, resulting in a vector that produces the same rotational effect. This equivalent force is defined as:
where the force acts through a moment arm within the plane of the face.
The total effective force acting against face ii is thus given by the sum of the perpendicular component of the net force and the equivalent force:
To characterize how close the system is to losing stability with respect to face ii, an angular metric is introduced. The instantaneous stability angle is defined as the angle between the effective force vector and the in-plane reference vector , computed using:
The geometric principles described above are illustrated in Figure 2, which provides a visual representation of the stability pyramid constructed from the vehicle’s ground contact points and the centre of mass, the construction of rollover axes, and the projection of the equivalent force vector used to assess rollover risk. The figure shows a typical lateral face defined by two support points and the CG, the corresponding rollover axis , the in-plane reference vector , and the effective force vector , which combines both net external force and moment effects. The stability angle is measured between and , indicating the proximity to rollover in that direction. Note that the stability angle is intentionally exaggerated in the figure to clearly visualize all vectors involved.
A positive angle indicates that the force projection remains within the support polygon, while negative values suggest that the system has lost contact support and tipping has begun.
The Table 1 depicts a template (e.g., an Excel sheet) where machine data are entered on the left side and results are produced on the right side.
Table 1.
Stability Pyramid calculation Template.
- On the left are the inputs: Vehicle geometry: wheelbase, track widths, and coordinates of wheel–ground contact points; Operating conditions: payload mass, boom elevation angle, and telescopic extension and dynamic parameters: overall centre-of-gravity coordinates (machine + load) and acceleration vectors (gravity and inertial).
- On the right are the outputs computed by the template: The canonical equations of the lateral planes of the stability pyramid and the stability margin angles for each plane (front, rear, left, and right).
The template is an operational tool: it lets the user input specific configurations and instantly obtain the metrics that quantify machine stability.
Table 2 summarizes the stability margins obtained for a representative set of twelve operating configurations, allowing direct comparison of how payload, boom position, and telescopic extension influence the proximity to rollover under the stability pyramid formulation. Some cells are intentionally left blank because ISO 22915-14 defines only a limited set of standardized test configurations, whereas the stability pyramid method can be applied to a broader range of parameter combinations. Each value indicates the additional rotation angle the machine can sustain before reaching the tipping condition about that specific plane. Smaller values denote a reduced stability margin, while larger ones indicate greater safety margins. This table provides a direct comparative overview of how different operating conditions affect the overall stability of the machine. In the last rows, the threshold values defined by ISO 22195-14 have been included for configurations that are closest to those specified by the standard. Here, it can be observed that the telehandler studied shows margins well above the thresholds imposed by the standard. The minimum margins have been highlighted in yellow.
Table 2.
Stability Margin Angles using Pyramid Stability Method for twelve representative telehandler operating configurations.
3.2. Global Load Transfer in Telehandlers
Global Load Transfer describes how the vertical support reactions of a telehandler are redistributed when the forces acting on its centre of gravity (CG) vary. This redistribution is the key mechanism governing the stability of the vehicle–load system. Several types of forces contribute to Global Load Transfer:
- (i)
- Gravitational force, always present and depends on the CG position.
- (ii)
- The geometric configuration of the vehicle–boom–load system, which continuously modifies the CG location, especially when lifting or extending the telescopic boom.
- (iii)
- Global inertial forces, generated by longitudinal or lateral accelerations when the vehicle accelerates, brakes, or turns.
- (iv)
- Functional inertial forces, arising from the motion of the telehandler’s movable components. A common example occurs with the vehicle at rest: if the operator lowers the boom at a high speed, the hydraulic system may limit or abruptly brake the motion for safety reasons. This sudden deceleration induces an additional inertial force on the load, which may temporarily disturb the distribution of vertical forces over the support points and momentarily reduce stability.
The interaction of these effects determines the magnitudes of the vertical reactions on the front wheels and on the oscillating rear axle, and defines how close the vehicle is to partial unloading or loss of ground contact.
Under real operating conditions, terrain inclination, the instantaneous position of the CG, and operational accelerations are all coupled, making it difficult to isolate their individual influence. To address this complexity, an equivalent representation is adopted based on a rigid platform with two degrees of freedom: a controlled inclination with respect to the horizontal plane (angle α) and an arbitrary orientation of the telehandler on the inclined surface (angle β). This idealization enables systematic reproduction of slopes and angular variations comparable to those encountered on uneven or irregular terrain.
Unlike simplified static approaches—which typically assume two-dimensional configurations and consider only gravitational effects—the formulation used in this work accounts for a general three-dimensional configuration in which gravitational, global inertial, and functional inertial forces act simultaneously. This approach, inspired by previous work such as [31], provides a unified framework for describing load transfer under realistic operating conditions.
This representation does not aim to reproduce every irregularity of real terrain, but rather to offer a clear and controlled setting for studying the combined action of gravity, global inertial effects, and boom-induced inertial actions. By treating α and β as independent parameters, it becomes possible to analyze in a structured way how each combination of orientations and forces influences Global Load Transfer. The following sections develop this formulation and introduce the associated load transfer matrix, showing how it can be used to directly obtain the vertical reactions at the support points from the forces applied at the centre of gravity.
Figure 3 illustrates the positions of the front and rear axles, the front-left and front-right wheels, the rear axle articulation point, and the centre of gravity (CG) on the inclination platform (α) and on the gyratory platform (β).
Figure 3.
Schematic diagram of the telehandler used in the quasi-static model. (a) Positions of the front and rear axles, the front-left and front-right wheels, the rear axle articulation point, and the centre of gravity (CG). (b) Reference frames, inclination of the supporting plane (Lift Platform), and orientation of the telehandler (Rotatory Platform).
3.2.1. Spatial Representation and Reference Frames
To describe the orientation of the telehandler in space and to formulate the load-transfer problem consistently, two reference frames are defined (see Figure 3):
- -
- Global frame (,: fixed to the ground, with oriented vertically and the axes − spanning the horizontal plane.
- -
- Local vehicle frame (,): fixed to the telehandler chassis. The axis is aligned with the longitudinal direction of the vehicle, points to the left side, and is normal to the chassis plane.
The telehandler is considered to operate on an inclined surface characterized by two angular parameters:
- -
- α (pitch): the inclination of the supporting plane with respect to the horizontal,
- -
- β (yaw): the orientation of the telehandler on that inclined plane, measured around the normal to the plane.
The relationship between the local and global frames is defined by a total rotation matrix , which combines the inclination α and the orientation β:
This transformation allows any vector expressed in the vehicle frame to be consistently mapped to the global frame. The complete derivation and explicit structure of are provided in Appendix A, enabling interested readers to reproduce the rotation sequence in detail.
This framework establishes the geometric foundations required to express all forces acting on the centre of gravity in a common reference frame before evaluating the resulting load transfer.
3.2.2. Forces Considered and Transformation to the Global Frame
With the reference frames defined, all forces acting on the telehandler are initially expressed in the local frame and subsequently transformed to the global frame using the operator . The forces contributing to Global Load Transfer are grouped as follows:
- (a)
- Gravitational loads. The gravitational force acts directly in the global vertical direction:
The direction varies with the terrain inclination, through the orientation transformations described before.
- (b)
- Global inertial loads. These arise from longitudinal and lateral accelerations during typical driving maneuvers. In the local frame:
Transformation to the global frame:
- (c)
- Functional inertial forces (movement of boom and load). These forces originate from the accelerations of internal moving masses, such as boom segments or the payload. For each moving mass i:
- -
- local inertial force
- -
- equivalent moment about the CG
- -
- Transformation to global frame:
- -
- The total action applied at the centre of gravity is then:
This formulation ensures that all gravitational, global inertial, and functional inertial effects are consistently expressed in the same reference frame. It also provides a complete and reproducible basis for the equilibrium equations developed in the next section.
3.2.3. Equilibrium Equations and Transfer Matrix Formulation
The load transfer problem is formulated by imposing equilibrium of vertical forces and moments about the centre of gravity (CG). The telehandler is assumed to be supported at three non-collinear contact points: front right (FR), front left (FL), and the rear axle pivot (P). Each contact provides a vertical reaction force.
The equilibrium of forces in the vertical direction can be written as:
where is the vertical component of the resultant of all forces applied at the CG, expressed in the global reference frame.
Taking moments about the CG, the contribution of a vertical reaction () applied at position to the moment about the (x)-axis is . The equilibrium equation reads:
where is the (x)-component of the resultant moment at the CG generated by forces not applied at (G). Similarly, the contribution of () to the moment about the (y)-axis is . With the adopted sign convention, the equilibrium condition becomes:
where denotes the corresponding component of the resultant moment at the CG.
Provided that the three support points are not collinear, the coefficient matrix is invertible and the reactions can be obtained as:
Once the geometric matrix {A} is defined, the computation of the support reactions becomes straightforward and computationally efficient, as all dynamic effects are contained in the righthand-side vector {b}.
To illustrate the capabilities of the proposed transfer-matrix formulation, a representative numerical example is presented. The objective of this example is not only to evaluate stability margins or to establish rollover criteria, but also to demonstrate how the developed formulation describes the evolution of the reaction forces at the telehandler support points under general conditions of load, terrain inclination, and vehicle orientation.
The analysed configuration corresponds to operating point EP7, as defined in Table 2. This configuration has been deliberately selected to provide a common reference with one of the cases, which are later used in the application of the stability pyramid method. The telehandler carries a payload of 1600 kg, the boom is raised to 25° with minimum telescopic extension, and the machine is positioned on an inclined platform with an inclination angle of α = 9.6°.
Figure 4 shows the vertical reaction forces at the three support points of the vehicle—front right (FR), front left (FL), and rear axle pivot (P)—as functions of the orientation angle β, which varies from 0° to 360°. Two loading conditions are superimposed in the same plot. Solid lines correspond to the case in which only gravitational forces are considered. Dashed lines represent the same configuration but including additional global inertial forces, namely a longitudinal deceleration and a simultaneous lateral acceleration
Figure 4.
(a) Vertical reaction forces at the support points FR, FL, and P as functions of the orientation angle β for configuration EP7 (payload 1600 kg, boom angle 25°, minimum extension, platform inclination α = 9.6°). Solid lines correspond to gravitational forces only, while dashed lines include additional global inertial effects (, ). (b) The right-hand plot shows the difference between both cases, highlighting the contribution of inertial forces to load transfer.
The selected acceleration values are not intended to reproduce typical operating conditions, but rather to deliberately amplify the effect of inertial forces in order to clearly visualize their relative influence and their dependence on vehicle orientation. In this way, the example allows the identification of those orientations for which inertial loads have a more significant impact on the reactions at the support points.
The left-hand plot presents the absolute values of the reaction forces at each support point for both loading conditions, highlighting how the combined effect of terrain inclination and vehicle orientation leads to significant variations in load distribution. The right-hand plot shows the difference between the two cases, isolating the contribution due exclusively to inertial forces.
In particular, the reference orientation β = 0° appears as a particularly critical condition under purely gravitational loading, as previously verified in Table 2 using the stability pyramid method.
This example demonstrates the ability of the proposed transfer matrix to efficiently and systematically analyse the evolution of support reactions under general three-dimensional configurations, coherently integrating gravitational and inertial effects as functions of terrain inclination and vehicle orientation.
3.3. Rear-Axle Non-Collinearity and Its Implications During Instability
Telehandler-type machines with a split-frame architecture—where the front chassis is supported by the two front wheels and a longitudinal pivot pin connecting it to the rear chassis- do not behave as single–degree-of-freedom mechanisms during the initial stages of lateral rollover.
In these configurations, the rear chassis typically consists of the oscillating rear axle and wheels, whose primary purpose is to maintain ground contact on uneven terrain. However, this articulation also plays a critical role in the machine’s stability behaviour.
3.3.1. Geometric Constraint Induced by Non-Collinearity
A fundamental aspect of the problem is that the longitudinal axis of the rear pivot is not collinear with the virtual roll axis defined by the pivot point P and the outer front wheel A.
Whenever this non-collinearity is present: the machine cannot rotate purely about the virtual roll axis V1; the structure becomes geometrically constrained and behaves temporarily as a hyper static system; a portion of the imposed rotation must be absorbed through secondary motions of the rear axle; rollover is ultimately governed by a transition to a second effective roll axis V2 once the pivot reaches its mechanical limit (Figure 5).
Figure 5.
(a) Structural schematics used for analysing lateral rollover in the telehandler. (a) Initial and rotated positions of the rear axle as the frontal chassis rolls about the virtual axis V1, defined by (points P-A), (b) Simplified representation (it’s not to scale for better viewing) showing the two rollover axes: the virtual roll axis V1 and the effective rollover axis V2, defined by the ground-contact points of the right-hand wheels.
This behaviour has direct implications for sensor calibration, definition of operational safety limits, and interpretation of stability measurements. Analyses relying solely on the virtual roll axis V1 may underestimate the onset of instability if the geometric coupling between the chassis and rear axle is not accounted for.
3.3.2. Methodological Framework
To describe how the rear axle accommodates the initial chassis roll, a geometric procedure is applied. The method quantifies the coupling between the virtual rotation of the chassis around the line PA and the compensatory oscillation of the rear axle required to preserve ground contact.
Figure 6.
Flowchart of the geometric procedure used to model the rear-axle kinematics during Phase I of rollover.
Table 3.
Relative displacements of the rear-wheel ground-contact points C (left) and D (right) obtained from the kinematic model.
- -
- Definition of reference geometry, establishing the positions of the pivot P, the outer front wheel A, and the rear wheels C and D.
- -
- Construction of the virtual roll axis using the unit vector along segment PA.
- -
- Rotation of the chassis around this axis, applied to the rear wheel coordinates through Rodrigues’ rotation formula. This transformation reveals the geometric incompatibility, as the rear wheels no longer satisfy the ground-contact condition.
- -
- Computation of the compensatory rotation of the rear axle, represented as a rotation about the longitudinal axis of the machine.
The required angle is obtained analytically by imposing the ground-contact condition for the lifted wheel.
- -
- Verification of the mechanical oscillation limit.
As long as ∣ϕ∣ remains within the permissible oscillation range (typically a few degrees, depending on the manufacturer), the machine stays in Phase I of rollover. Once the mechanical limit is reached, the rear axle becomes rigid, and the system transitions to Phase II, governed by the effective roll axis V2.
The combination of these steps provides a complete kinematic description of the rear-axle response during the early stages of lateral instability. The next diagram of Figure 6 summarizes the computation of the virtual roll axis, the chassis rotation around V1, the lifted rear-wheel positions, and the compensatory rear-axle rotation required to restore ground contact.
3.3.3. Interpretation of Results
The computed trajectories of the rear wheel contact points (Figure 3) show that the rear axle must undergo coordinated longitudinal and vertical displacements to accommodate the imposed chassis roll. During Phase I, the left rear wheel moves slightly forward, while the right rear wheel moves backward by a larger amount, enabling the machine to follow the virtual roll axis V1 until the oscillating joint reaches its mechanical stop. Beyond this threshold, the rear axle can no longer compensate for the imposed rotation, triggering the transition to Phase II and the shift of the effective roll axis to V2.
This behaviour is consistent with the two-stage rollover mechanism described by Baker and Guzzomi in their work for pivoted-axle agricultural tractors [32] and confirms the analogous role of the oscillating rear axle in telehandlers: a stabilizing element during Phase I, and a geometric constraint once its rotational capacity is exhausted.
4. Virtual Tilt-Rotary Test Platform for the Dynamic Stability Analysis of Telehandlers
To analyze telehandler behavior under controlled inclined configurations, a virtual tilt–rotary test platform was developed and integrated with the previously validated BG3D telehandler model. The objective of this platform is to reproduce standardized and non-standardized inclination scenarios within a computationally controlled environment, avoiding the need for full virtual terrain modelling.
4.1. Architecture of the Virtual Platform
The virtual Architecture of the Virtual Platform consists of two principal degrees of freedom:
- A tilting base structure, hydraulically actuated, capable of reproducing controlled longitudinal or lateral inclinations (tilt angle α).
- A rotary platform mounted on the tilting base, providing rotation about a vertical axis (orientation angle β).
The telehandler is mounted on the upper rotary platform through explicitly defined wheel–platform contact conditions. This configuration enables arbitrary combinations of inclination (α) and orientation (β), reproducing the geometric conditions associated with ISO 22915-14 testing as well as extended parametric analyses.
An optional subsystem consisting of four independently actuated plates can be incorporated to represent local terrain irregularities. This functionality, inspired by experimental concepts proposed in agricultural machinery research ([33] and later refined by [34], is not addressed in the present study.
Compared to full terrain-based simulations, the tilt–rotary approach offers improved numerical robustness and parameter isolation. Inclination and orientation can be controlled independently, facilitating systematic exploration of rollover thresholds without introducing stochastic contact effects associated with complex surface meshes.
4.2. Integration with the BG3D Telehandler Model
The telehandler model employed in this study corresponds to the high-fidelity three-dimensional Bond Graph (3D BG) multibody representation (Figure 7) introduced in [2]. The mechanical subsystem is formulated as a spatial multibody assembly, while hydraulic actuation is represented using one-dimensional Bond Graph elements. This multidomain formulation ensures energetic consistency between mechanical and hydraulic domains.
Figure 7.
Multibody virtual BG3D model of the telehandler, according to Figure 6 of Puras et al. (2024) [2].
In the present work, the telehandler model is rigidly coupled to the virtual tilt–rotary platform (Figure 8) described in Section 4.1. The integration is performed by defining explicit wheel–platform contact constraints that prevent sliding while allowing the evolution of vertical reaction forces. Alternative boundary condition formulations were analysed to identify those that best reproduce the mechanical behaviour observed in experimental configurations.
Figure 8.
Multibody virtual BG3D model of the Tilt-Rotary platform and telehandler sub model connected.
This integrated configuration enables systematic exploration of stability behaviour under arbitrary combinations of inclination angle (α) and orientation angle (β). For illustration purposes, Figure 9 shows the evolution of vertical wheel reactions during a complete rotation cycle (β = 0–360°) under fixed platform inclination (α = 25°). The results allow identification of angular sectors in which one or more wheels approach loss of contact.
Figure 9.
Vertical reaction forces (z) at each wheel during a full vehicle rotation (β = 0–360°) on an inclined platform, for specific operating conditions of payload mass = 0 kg, boom elevation angle = 10°, platform inclination angle α = 25°, and for different boundary conditions. Boundary conditions: (a) with lateral (y axis) constraints on the right-hand wheels and longitudinal (x axis) constraints on both rear wheels. (b) with lateral constraints on the right-hand wheels and a longitudinal constraint applied only to the rear right wheel.
Figure 10 presents a comparison between wheel reactions obtained using the quasi-static Transfer Matrix (TM) formulation introduced in Section 3 and those predicted by the Virtual Model (VM). The VM captures additional geometric and structural effects associated with spatial articulation and actual mass distribution, which are not represented in the simplified TM approach.
Figure 10.
(a) Vertical wheel reaction forces predicted by the Transfer Matrix (TM) and the Virtual Model (VM) as a function of the orientation angle β. Dashed lines correspond to TM results and solid lines to VM results. (b) Difference in vertical reaction forces between the two approaches.
Further modelling assumptions, parameter identification procedures, and numerical implementation details are summarised in Section 4.3.
4.3. Model Assumptions and Parameter Identification
The Bond Graph 3D (BG3D) virtual model employed in this study was previously developed and experimentally validated in detail [2]. For completeness and to improve reproducibility, the principal modelling assumptions and parameter identification procedures are summarized below.
The telehandler is represented as a spatial multibody system composed of 22 rigid bodies interconnected through kinematic joints. All structural components of the telescopic boom are assumed to be rigid. This assumption is supported by experimental vibration measurements (100 Hz sampling), which identified dominant natural frequencies around 37 Hz—significantly higher than the characteristic frequencies associated with load-handling maneuvers. Structural flexibility, therefore, does not influence the quasi-static stability scenarios analysed in this work.
The soil/tire interaction models the tire as a nonlinear system with multiple inputs (slip, angles, and load forces) and outputs (longitudinal/lateral forces and tire moments). To define the “black box” linking these inputs and outputs in both steady and transient conditions, we apply Pacejka’s Magic Formula Tire model. This model is fed with the platform’s translational velocity, the velocity at the tire-ground contact point, and the rotational variables of the wheel axle. The soil profile is represented as a virtual plane.
Given the focus on stationary longitudinal and lateral stability under load-handling conditions, only the vertical stiffness and damping components significantly affect the results. The vertical stiffness was initially estimated from literature and subsequently refined using manufacturer data and experimental observations, leading to an adopted value of 600 kN/m, consistent with measured vertical deflections below 5 mm under nominal loading. The damping coefficient (1–10 kNs/m range in literature) was calibrated against experimental dynamic responses, resulting in a value approximately one order of magnitude higher than initial estimates to suppress non-physical oscillatory behaviour.
The hydraulic subsystem is modelled using lumped-volume theory, assuming spatially uniform pressure within each control volume and constant oil bulk modulus. Acoustic wave propagation effects are neglected. Flow through throttling elements is governed by Bernoulli-type relations based on pressure differentials. End-stop conditions in hydraulic cylinders and valve-seat interactions are explicitly represented.
Mass properties (mass, centre-of-gravity location, inertia tensors) were derived from geometric and manufacturer data. The fork load is modelled as a homogeneous cubic volume with variable density, allowing reproduction of experimental loading conditions within the 0–1600 kg range.
The complete formulation results in a coupled differential–algebraic equation (DAE) system derived from Newton–Euler equations and constraint relations. Numerical integration was performed in 20-SIM using a Modified Backward Differentiation Formula (MBDF), with absolute and relative error tolerances set to 10−4, minimum time step of 1×10⁻¹² s, and maximum time step of 10−3 s.
Previous validation under controlled loading configurations showed discrepancies generally below ±10% relative to nominal wheel loads, consistent with the best levels of agreement reported in the available telehandler literature (e.g., [22]). The present study builds upon this validated model to analyse inclined ISO 22915-14 configurations and rollover mode transitions.
4.4. Numerical Post-Processing Capabilities
Beyond stability threshold identification, the integrated virtual model enables advanced numerical post-processing operations. In particular, it allows estimation of the global centre of gravity (CG) of the telehandler–platform system through a computational equivalent of the ISO double-weighing method, detailed in Appendix B
This procedure is based on processing the vertical reaction forces obtained under level and inclined configurations, following a logic analogous to that defined in ISO standards for CG determination. By combining reaction force distributions and known geometric references, the spatial coordinates of the global CG can be determined without direct physical weighing
Figure 11 illustrates the evolution of the global CG coordinates during boom elevation for different payload masses and telescopic extensions. The vertical coordinate (Z) exhibits an approximately linear increase with boom angle, reflecting structural elevation. The longitudinal coordinate (X) follows a nonlinear trend resulting from the combined effects of telescopic extension and boom kinematics. In contrast, the lateral coordinate (Y) remains nearly constant, indicating that boom elevation has negligible influence on lateral CG displacement under symmetric loading conditions.
Figure 11.
Evolution of the global centre of gravity (CG) coordinates (X, Y, Z) during boom elevation, considering different telescopic extensions and payload configurations, obtained using the virtual tilt–rotary platform model.
Minor oscillations observed at the beginning and end of each trajectory correspond to transient dynamic effects associated with acceleration and deceleration phases, primarily influenced by tyre compliance and global vehicle response.
5. Experimental Stability Tests of the Telehandler
The experimental estimation of telehandler stability conditions is a fundamental aspect for both operational safety and the development of advanced control and assistance systems. From a regulatory standpoint, this topic is addressed through a set of complementary standards, namely EN 1459-8 [35], EN 15000 [29], and ISO 22915-14 [3], each focusing on different but interrelated aspects of machine safety and stability.
The EN 1459-8 standard defines static and dynamic test procedures aimed at verifying the structural integrity of rough-terrain variable-reach trucks (RTVRs), including telehandlers. The static test assesses the ability of the machine to withstand 125% of nominal loads—designated as Q1, Q2, and Q3, corresponding to different combinations of boom extension, lifting height, and load position—without permanent deformation. The dynamic test requires the execution of complete operating cycles at maximum engine speed with 100% of the nominal load, ensuring structural robustness under representative working conditions.
The EN 15000 standard, in contrast, specifies the technical requirements and verification procedures for longitudinal load moment control (LLMC) systems and load moment indicators (LLMI), which are typically implemented via a load cell installed on the rear axle. These systems are designed to prevent the machine from exceeding its longitudinal stability limits during lifting and handling operations.
Although both EN 1459-8 and EN 15000 refer to ISO 22915-14 for stability-related testing, it is important to note that ISO 22915-14 is the only standard explicitly dedicated to the experimental assessment of telehandler stability. It defines five standardized test configurations conducted on an inclinable platform, where the vehicle remains stationary while the platform is progressively tilted until a critical condition—typically wheel lift-off—is reached. This approach characterizes stability under controlled, quasi-static conditions, but does not account for dynamic manoeuvres or travel-related scenarios that frequently occur in real field operation.
Within this normative framework, the experimental campaign presented in this work serves a dual purpose. First, it confirms compliance of the tested telehandler with the stability requirements defined in ISO 22915-14. Second, and more importantly from a scientific perspective, the experimental data provide a solid reference for interpretation using the high-fidelity virtual model based on 3D Bond Graphs. This enables a deeper understanding of the mechanisms governing stability and establishes a foundation for the future derivation of simplified predictive models. While such predictive models are not developed within the scope of the present paper, their conceptual formulation and future applicability are explicitly supported by the experimental–numerical framework presented here and will be addressed in subsequent work.
It should also be emphasized that the ISO-based tests discussed in this chapter do not represent the full set of experiments conducted during the development of the virtual model. Additional experimental configurations were performed to support model calibration and refinement; however, only the standardized tests relevant for subsequent comparison and analysis are reported here for clarity and conciseness.
Test Methodology and Experimental Results
The experimental campaign was carried out in collaboration with the telehandler manufacturer, using its certified inclinable test platform, which is routinely employed for conformity testing in accordance with ISO standards. The platform is fully instrumented and complies with the dimensional and performance requirements specified in ISO 22915-14, enabling accurate reproduction of the five prescribed stability test configurations.
During testing, the telehandler was rigidly fixed to the platform and positioned according to the specific test type (longitudinal, transverse, or diagonal orientation). The platform was then progressively tilted using a hydraulic actuator until the onset of instability was detected. Each test was repeated for multiple boom heights and load configurations, ensuring repeatability while strictly adhering to safety measures protecting both personnel and equipment.
Representative boom motions were included in the procedure, consisting of raising and lowering operations combined with incremental telescopic extensions, ranging from fully retracted to fully extended positions (A, B, C, D, E, and F), in 250 mm steps. The applied loads were 0, 640, 1000, and 1600 kg, while tire pressure was maintained at approximately 6 bar throughout all experiments.
A detailed description of the instrumentation installed on the telehandler prototype can be found in Puras et al. [2] (2024). For the present study, the experimental setup shown in Figure 12 focused on three primary data sources:
Figure 12.
(a) Inclination platform. (b) Example of test on inclination platform: ISO22915-14 Test 3 configuration.
- -
- The rear axle load cell, used by the onboard control system to prevent overturning,
- -
- The platform inclinometer, measuring the tilt angle, and
- -
- Portable wheel scales, employed when individual wheel loads were required.
Prior to stability testing, the rear axle load cell was calibrated to ensure measurement accuracy. The resulting calibration curve is presented in Figure 13 and was used as a reference for all subsequent experimental data.
Figure 13.
Experimental calibration curve of the load cell located at the rear axle.
According to ISO 22915-14, Test Type 1 determines the maximum longitudinal inclination angle that the telehandler can withstand under load before losing stability. In this configuration, the machine is positioned perpendicular to the platform’s tilt axis and faces the rotation axis, simulating a longitudinal slope.
With the platform initially horizontal, the telehandler—equipped with a standardized fork and loaded up to 1600 kg—was set to a predefined boom elevation angle, typically increased in 10° increments. The telescopic boom was then progressively extended until the load moment control system halted further motion, in accordance with EN 15000 [28] limits. Once this condition was reached, the platform was slowly tilted in the longitudinal direction until one of the rear wheels lost contact with the surface, indicating loss of reaction. The corresponding tilt angle was recorded as the critical stability angle.
The experimental results obtained for Test Type 1 are summarized in Table 4, which reports the measured critical inclination angles and corresponding wheel load distributions.
Table 4.
ISO22915-14 Test1 stability experimental results (load cell cut).
The same general procedure was applied to Test Types 2 to 5, with the telehandler configured according to the specific requirements of each test, including orientation relative to the platform’s tilt axis, boom elevation, telescopic extension, and applied load. These configurations represent extreme operating conditions, such as fully raised or horizontal boom positions, fully retracted or fully extended telescopic sections, and either maximum or null load. The primary distinction among these tests lies in the orientation of the machine with respect to the platform inclination direction.
To illustrate these configurations, Figure 14 and Figure 15 present representative examples of Tests 2 to 5, highlighting the diversity of stability conditions investigated.
Figure 14.
(a) Test 2: Slope inclination 22%, load 1600 kg, Travelling position, Maximum retraction of the boom, full rearward fork. (b) Test 3: Slope inclination 12%, load 1600 kg, Maximum inclination and Maximum extension of the boom.
Figure 15.
(a) Test 4: Slope inclination 50%, without load, Travelling position, Maximum retraction of the boom, full rearward fork. (b) Test 5: Slope inclination 10%, without load, Maximum inclination, and Maximum extension of the boom.
In all cases, the platform was tilted slowly until the onset of instability was detected, typically corresponding to the initial lift-off of one wheel. The experimental results for Test Types 2 to 5 are summarized in Table 5, which reports the measured tipping angles and wheel reaction distributions, together with reference limits defined by ISO 22915-14.
Table 5.
ISO22915-14 Test 2, 3, 4, and 5 stability experimental results.
Overall, the experimental campaign confirmed that the tested telehandler complies with the stability requirements specified in ISO 22915-14 across all standardized configurations. At the same time, the results reveal noticeable variations in stability behaviour depending on boom position, applied load, and machine orientation. These observations indicate that telehandler stability arises from a complex interaction between geometry, load distribution, and structural flexibility—effects that cannot be fully captured by quasi-static testing alone.
For this reason, the following chapter employs the virtual telehandler model to interpret the experimental results in greater depth, assess the influence of structural and operational parameters, and extract insights that support the future development of simplified predictive models and real-time operator assistance strategies.
6. Analysis of Experimental Results with Virtual Model Assistance
The previous chapter described the experimental methodology used to evaluate the stability of telehandlers in accordance with ISO 22915-14. The tests were designed to identify the limiting stability conditions of the machine under different combinations of load, boom angle, and telescopic extension, using a tilting platform that allows controlled reproduction of critical rollover scenarios.
The main objective of this chapter is to provide an integrated interpretation in which experimental results and virtual simulation complement each other, allowing a deeper understanding of the mechanisms governing telehandler stability under quasi-static critical conditions and facilitating the interpretation of differences observed between idealised behaviour and the actual response of the machine.
6.1. Type 1 Test—Load Handling in the Least Stable Combinations
The Type 1 Test, defined by ISO 22915-14, aims to evaluate telehandler stability during load handling operations such as stacking or load recovery, which may occur on sloping ground and represent particularly unfavourable combinations of load, boom height, and telescopic extension. The test allows the determination of a stability limit under controlled conditions, with the progressive inclination of the platform representing the severity of the operational scenario.
In the experimental methodology, the telehandler is initially positioned on the tilting platform in a horizontal orientation (platform without inclination), with its longitudinal axis perpendicular to the tilting axis. The telescopic boom is then raised to a predefined angle and progressively extended until the signal from the load cell installed on the rear axle blocks the system motion. This threshold does not define the minimum admissible stability condition of the vehicle, but rather establishes a specific and repeatable operational configuration used as the starting point of the test. This initial configuration is adopted for experimental and safety reasons, ensuring reproducibility of the procedure.
Once this initial configuration is reached, the test itself begins: the platform is progressively inclined until the loss of contact of one wheel with the supporting surface is detected, a condition adopted as the operational criterion for the onset of instability and therefore as the final condition of the test. Throughout the procedure, the load mass, boom elevation angle, telescopic extension, and platform inclination angle are recorded. This set of tests was repeated for different combinations of boom angle, telescopic extension, and applied load (0, 840, 1135, and 1600 kg), as described in Section Test Methodology and Experimental Results.
The same conditions defined experimentally as the initial configuration of the test were used as direct inputs to the virtual model, which represents both the telehandler and the tilting platform in an integrated manner. Based on these inputs—boom angle, telescopic extension, and load—the virtual model computes the evolution of the vertical reaction at the left rear wheel (RL) as a function of the platform inclination angle. For each configuration, this relationship can be approximated by a linear expression:
where the term (B) represents the RL reaction corresponding to the horizontal platform position for each specific test.
Figure 16 shows the curves obtained with the virtual model using the experimental initial conditions as inputs. Solid lines represent the evolution of the RL reaction for different boom elevation angles. It can be observed that the initial values of the RL reaction—i.e., the term (B) for each curve—do not exactly coincide with the load cell cut-off threshold (2600 N). This dispersion highlights the inherent difficulty of experimentally reproducing an identical initial configuration, even under a carefully controlled protocol.
Figure 16.
Type 1 Test according to ISO 22915-14 [3]. (a) Evolution of the left rear wheel reaction (RL) obtained with the virtual model for different initial configurations. (b) Normalized results: comparison between experimental values, virtual model, and ISO normative limit.
The combined analysis of experimental data and virtual model results confirms that these differences are not due to numerical inaccuracies, but rather to the intrinsic nature of the experimental procedure. System sensitivity to small variations in boom angle or telescopic extension, together with the dynamic response of the assembly—including tyre elasticity and slight structural rocking—introduces unavoidable variability in the measured values. Nevertheless, this variability does not prevent verification that the telehandler fully complies with the stability requirements of ISO 22915-14 for all tested configurations.
To provide a homogeneous criterion allowing consistent comparison and analysis of the different tests, a normalisation procedure is introduced. In this process, the value (B) of each curve is replaced by the fixed threshold of 2600 N corresponding to the load cell blocking signal. This normalisation yields a set of comparable curves, represented by dashed lines in Figure 16a, describing in a consistent manner how the RL reaction evolves as a function of platform inclination for the different initial test conditions.
The normalised results are summarised in Figure 16b, together with the experimental values and the minimum stability limit established by ISO 22915-14. This representation clearly shows that the telehandler exceeds the normative requirements in all analysed cases. Furthermore, the figure highlights that the experimental values obtained using the tilting platform are conservative, as they systematically lie below the stability limits conceptually estimated by the virtual model. This conservative character is consistent with the philosophy of the normative test and reinforces its validity as a stability verification method.
Overall, the Type 1 Test demonstrates that, despite the inherent variability of experimentation, the procedure provides robust safety margins aligned with normative objectives. The virtual model not only confirms compliance with the standard, but also offers a complementary and more interpretative view of system behaviour, enabling understanding of how the RL wheel reaction varies with platform inclination and different initial test conditions—information that cannot be directly inferred from isolated experimental results.
6.2. Type 2 Test—Longitudinal Stability During Load Travel
The Type 2 Test defined in ISO 22915-14 aims to evaluate the longitudinal stability of the telehandler during load travel. In this test, the machine is placed on a tilting platform with its longitudinal axis perpendicular to the inclination axis, reproducing a longitudinal slope. The standard prescribes that the forks be fully tilted backwards and that the heel height be set at 300 mm above the platform plane, with the nominal load applied at the centre of the forks.
In the present work, the analysis is approached starting from the virtual model of the telehandler and the tilting platform, which allows a systematic study of the relationship between boom geometry, centre of gravity position, and longitudinal stability. In particular, the virtual model is used to establish the relationship between boom elevation angle and fork heel height, as shown in Figure 17a. This representation makes it possible to identify different configurations that are geometrically and stability-wise equivalent, including both the condition explicitly prescribed by the standard (boom angle of −5°, corresponding to a heel height of 300 mm) and other common operational configurations.
Figure 17.
Type 2 Test according to ISO 22915-14. (a) Relationship between boom elevation angle and fork heel height obtained with the virtual model. (b) Left rear wheel reaction (RL) versus platform inclination angle: comparison between virtual model, ISO normative limit, and experimental result with load cell threshold.
During the experimental campaign, the activation of the load cell threshold installed on the rear axle (2600 N) was adopted as the operational criterion defining the test configuration. This choice was considered appropriate, first for consistency with the methodology applied in the Type 1 Test, and second because in real operating conditions, it is common to travel with the forks slightly raised, especially on uneven terrain. In this sense, the configuration defined by the load cell threshold can be regarded as practical, repeatable, and conservative, as it places the centre of gravity in an unfavourable position from the point of view of longitudinal overturning moment.
From this initial configuration, the platform was progressively inclined until the loss of contact of one of the rear wheels occurred, and the critical inclination angle was recorded. Figure 17b shows the evolution of the RL reaction as a function of platform inclination, comparing virtual model results with the minimum value required by ISO 22915-14 (12.5°; green point) and the experimental value (16.33°) corresponding to the configuration defined by the load cell threshold (black point).
The results show good agreement between the behaviour predicted by the virtual model and the experimental values. In particular, the experimental result lies below the numerical prediction, confirming the conservative nature of the adopted experimental procedure. At the same time, the virtual model provides a clear conceptual view of how the RL reaction evolves with platform inclination for different boom configurations—information that cannot be obtained directly from isolated experimental measurements.
Overall, the results in Figure 17b confirm that the telehandler comfortably meets the longitudinal stability requirements established by ISO 22915-14. They also suggest that the employed methodology could be considered as a possible extension or complement to the current normative test formulation, providing additional criteria for evaluating longitudinal stability under real operating conditions and enabling a more comprehensive interpretation of vehicle behaviour.
6.3. Lateral Tests: Types 3 and 5 According to ISO 22915-14
The lateral stability tests corresponding to Types 3 and 5 defined in ISO 22915-14 are intended to evaluate telehandler behaviour under geometric configurations that induce critical lateral rollover conditions during load handling and recovery operations. In these tests, the machine must be oriented such that the lateral rollover axis V1—defined by the front axle pivot point (P) and the outer front wheel (FR)—is parallel to the tilting axis of the platform, reproducing a lateral slope condition in accordance with the normative definition.
Unlike the Type 5 Test, for which the standard explicitly prescribes the evaluation of lateral stability at maximum boom elevation without load, the Type 3 Test does not explicitly define a procedure for identifying the most unfavourable combination of boom elevation, telescopic extension, and load. In this context, and in line with the methodology adopted in previous sections, the present work first employs the virtual telehandler model to analyse lateral stability over a representative range of operational configurations. This analysis identified that the condition associated with maximum boom elevation and maximum telescopic extension represents the most critical situation from a lateral stability perspective and is therefore the most appropriate for experimental testing.
Based on this, in the experimental campaign, the boom was raised to 62° and fully extended (1240 mm), applying a load of 1600 kg for the Type 3 Test and a no-load condition for the Type 5 Test. The measured critical inclination angles were 8.14° and 7.86°, respectively—values clearly above the minimum requirements of ISO 22915-14, which specifies reference slopes of 12% (≈6.8°) for Type 3 and 10% (≈5.7°) for Type 5—thus confirming compliance with the normative lateral stability requirements (Figure 18).
Figure 18.
Type 3 and 5 Test according to ISO 22915-14. (a) Wheel reactions as a function of machine orientation for the Type 3 Test (1600 kg) and Type 5 Test (0 kg), with maximum boom elevation (62°) and full extension. (b) Wheel reactions as a function of orientation for the Type 3 and Type 5 Tests with boom elevation reduced to 52° and full extension.
Comparative analysis of the experimental results reveals a behaviour that may appear counterintuitive at first glance: for high boom elevations, the critical inclination angle is slightly higher in the loaded condition than in the unloaded condition. This behaviour does not imply a general improvement of stability due to the presence of load, but rather reflects the geometry of the assembly and the effective position of the global centre of gravity, strongly influenced by boom kinematics and the contribution of the load centre of gravity relative to the lateral rollover axis.
To further interpret this behaviour, the virtual telehandler model integrated with the tilting and rotating platform was used to analyse in detail the evolution of wheel reactions for different orientations and load configurations. Results corresponding to the experimental maximum elevation configuration (62°) are presented in Figure 18a. The figure shows that the minimum reaction at the left front wheel (FL) occurs for an orientation close to 250°, which coincides with the orientation prescribed by ISO 22915-14. Furthermore, the FL reaction is lower in the no-load condition than in the 1600 kg load condition, in agreement with both experimental results and normative formulation, identifying the no-load condition as particularly critical for lateral stability.
For the Type 3 Test, it is also observed that although the rear wheel reactions (RL and RR) are initially higher than FL, they progressively decrease with orientation and reach, for orientations above 250°, values comparable in order of magnitude. Since the load cell is installed on the rear axle, this behaviour highlights that the protection system may limit machine functionality even in configurations where lateral rollover risk is governed by the outer front wheel.
An additional relevant result is obtained when considering a second numerical simulation in which only the boom elevation angle is reduced from 62° to 52°, while keeping all other parameters constant (Figure 18b). In this configuration, the Type 3 Test shows a qualitative change in the reaction pattern, with the rear wheels exhibiting lower reactions than the FL wheel, reversing the behaviour observed at maximum elevation. This change does not occur in the Type 5 Test, whose response remains consistent. Moreover, simulations reveal that for orientations between 0–90° and 270–360°, instability situations associated with lifting of the rear wheels may occur, in agreement with the results obtained in the Type 1 Test when analysing longitudinal stability (β = 0°). These findings indicate a progressive transition from behaviour dominated by lateral stability to situations that are conceptually critical from a longitudinal stability standpoint, depending on boom elevation.
Overall, the combined analysis using virtual simulation and experimental testing not only verifies compliance with ISO 22915-14 but also highlights the practical limitations of exhaustively identifying critical configurations through physical testing alone. In this context, the virtual model is consolidated as a complementary tool for guiding test planning, reducing the number of required experiments, and improving safety and efficiency of experimental campaigns, without replacing the experimental verification required by the standard.
6.4. Lateral Stability Test (Type 4 According to ISO 22915-14)
The Type 4 lateral stability test defined in ISO 22915-14 aims to evaluate telehandler stability during transport conditions on sloping ground, considering the machine without load on the forks. Unlike the Type 3 and 5 Tests, this test is performed with the telescopic boom retracted, minimum telescopic displacement, and slightly raised so as not to interfere with the ground during platform inclination. The machine is oriented with its longitudinal axis forming an angle β = 250° with respect to the tilting axis, consistent with the orientation prescribed for lateral stability tests.
Although the structural architecture of the telehandler is the same as in the Type 3 and 5 Tests, the behaviour observed in the Type 4 Test is substantially different. This difference is not merely associated with the presence of the rear axle articulation, but with the kinematic regime reached during the test. While in the Type 3 and 5 Tests, instability occurs at relatively small inclination angles, comparable to the free articulation range of the pivot, in the Type 4 Test, significantly larger inclinations are reached. This allows full exploitation of the articulation kinematics and even activation of mechanical stops, leading to a transition between different rollover modes.
As a preliminary estimate, the stability pyramid method was applied to evaluate the angular margin associated with different virtual rollover axes. For axis V1, defined by the front axle pivot point (P) and the outer front wheel (FR), a critical angle of approximately 27.7° is obtained. For axis V2, defined by the right-side wheels (FR–RR), the margin increases to values close to 40° (Table 2 (conf. EP1)). These values, much higher than those obtained in the Type 3 and 5 Tests, anticipate behaviour governed by mechanisms different from those observed in lateral load-handling tests.
To analyse these mechanisms in detail, the virtual telehandler model was employed, considering three idealised configurations of the chassis–rear axle assembly:
- (A).
- free pivot,
- (B).
- locked pivot, with rear axle and front chassis behaving as a rigid body, and
- (C).
- pivot with articulation limited by mechanical stops (±7°).
This approach allows isolation of the effect of pivot kinematics and analysis of transitions between rollover modes.
Simulation results show that in configuration A (free pivot), instability is necessarily governed by the virtual rollover axis V1. In this idealised configuration, complete articulation freedom prevents transmission of forces that would activate an alternative rollover axis, so the system can only overturn about V1. Conversely, in configuration B (locked pivot), the chassis–rear axle assembly behaves as a rigid body, eliminating the rollover mode associated with V1 and causing lateral stability to be governed directly by axis V2. These behaviours are illustrated in Figure 19a,b, where wheel reactions are shown as a function of platform inclination angle.
Figure 19.
Type 4 Test according to ISO 22915-14. Virtual model results for (a) Configuration A: rear axle rigidly connected to the front chassis, and (b) Configuration B: freely articulated rear axle. Wheel reactions are shown as a function of platform inclination angle, highlighting critical angles associated with rollover axes V1 and V2.
Configuration C, which more realistically represents vehicle behaviour by including mechanical stops, exhibits a progressive transition between both modes. In an initial phase, the system evolves following the rollover mode associated with V1 until the articulation limit is reached. Beyond this point, contact with the mechanical stop induces a structural reconfiguration, and the stability mechanism becomes governed by axis V2. This transition explains the high experimentally observed critical angle, around 31.1°, clearly exceeding the free articulation range of the pivot.
It should be noted that although the geometric articulation range of the pivot is approximately ±7°, effective activation of the stop does not depend solely on reaching this angular value. The non-collinearity between the pivot pin axis and the virtual rollover axis V1 introduces a hyperstatic condition requiring three-dimensional reconfiguration of the chassis–rear axle assembly. As a result, an additional increase in platform inclination is required for the system to evolve toward the rollover mode defined by V2. This phenomenon is clearly observed in the virtual model results presented in Figure 20.
Figure 20.
Type 4 Test according to ISO 22915-14. Virtual model results for configuration C with pivot mechanical stop (±7°): (a) geometric evolution of the articulation, and (b) evolution of wheel reactions on the left side. The transition between the lateral stability mode defined by axis V1 and the mode associated with axis V2 after stop contact is observed.
Comparison between experimental results and virtual model predictions shows excellent agreement in terms of both critical angle and sequence of activated mechanisms. This confirms the validity of the virtual model as a support tool for interpreting the Type 4 Test and demonstrates that, in this case, the initial loss of wheel contact is not a sufficient criterion to characterise global stability; consideration of the transition between rollover modes is essential. Overall, the Type 4 Test highlights the decisive influence of rear axle articulation on telehandler lateral stability under transport conditions and demonstrates that combining normative testing with virtual simulation is fundamental for detailed interpretation of different lateral instability modes and for understanding the interaction between the front chassis and the pivoting rear axle. This approach enables a more rigorous analysis of rollover mechanisms and transitions between virtual stability axes, providing a level of detail that, to the authors’ knowledge, has not been explicitly documented in the technical literature on telehandlers.
7. Conclusions and Final Remarks
This paper has presented a structured investigation of telehandler stability under inclined terrain conditions, following a sequential methodological approach. In a first stage, stability was analyzed using quasi-static methods based on force and moment equilibrium, including the load transfer matrix and the stability pyramid. These approaches account for gravitational and inertial effects through equivalent external forces and moments applied at the global centre of gravity, providing an efficient framework for identifying critical configurations and estimating proximity to rollover thresholds.
The study demonstrates, however, that despite their practical value, quasi-static methods exhibit intrinsic limitations when applied to structurally complex machines such as telehandlers equipped with a pivoting rear axle. In particular, they require a priori assumptions regarding the effective rollover axis and cannot fully capture the interaction between rear axle articulation limits, tire compliance, and the spatial evolution of the support polygon.
To overcome these limitations, a dynamic multibody model based on the three-dimensional Bond Graph (3D BG) methodology was implemented. This contribution builds directly upon previous work by the authors [2], in which a validated virtual telehandler model was developed using the same formalism. In the present study, the model was extended through the incorporation of an active tilt-and-rotation platform, referred to as the Virtual Tilt-Rotary Test Platform, enabling systematic analysis of machine orientation relative to the inclination axis under ISO 22915-14 configurations. The entire system—vehicle and platform—was modelled consistently within a unified nonlinear three-dimensional framework.
Validation against the stability tests defined in ISO 22915-14 showed very good agreement between experimental results and numerical predictions, both in terms of critical inclination angles and rollover sequences. In longitudinal tests (Types 1 and 2), the virtual model complemented experimental data by enabling normalization of results and providing a mechanical explanation for the conservative nature of the measured stability margins. In lateral configurations (Types 3 and 5), simulations clarified apparently counterintuitive behaviors and revealed the influence of rear axle articulation limits and structural compliance on the effective support geometry. The Type 4 test highlighted the decisive role of rear axle mechanical stops, demonstrating the coexistence of multiple stability modes and the possibility of transitions between distinct virtual rollover axes.
Beyond normative verification, the principal conceptual contribution of this study lies in the explicit identification and dynamic interpretation of rollover axis transitions induced by rear axle articulation under spatially inclined ISO configurations. While previous investigations on off-road vehicle stability have primarily addressed forward driving conditions or horizontal quasi-static load assessments, the present work shows that, in telehandlers with evolving mass distribution due to boom motion and load variation, the interaction between rear axle articulation limits, centre-of-gravity migration, and platform orientation may generate condition-dependent transitions between distinct three-dimensional rollover regimes. To the authors’ knowledge, this conditional structural mechanism has not been explicitly formalized within a nonlinear spatial dynamic framework for telehandler stability assessment, although conceptually related phenomena have been discussed by Guzzomi [6] in agricultural vehicles with pivoting axles.
The authors fully acknowledge that virtual dynamic simulation cannot replace experimental verification required for homologation under current regulatory standards. Nevertheless, the results clearly demonstrate that high-fidelity dynamic modelling constitutes a powerful complementary tool to improve interpretation of normative tests, reduce unnecessary experimental campaigns, and identify critical operating configurations prior to physical validation.
Finally, the physical insight gained from the validated dynamic model provides a solid basis for future developments in predictive stability assessment and operator assistance systems. Modern telehandlers increasingly operate with a wide variety of attachments beyond conventional forks, leading to significant variations in mass distribution and stability margins. By identifying dominant instability mechanisms through high-fidelity simulation, it becomes possible to derive simplified, control-oriented indicators suitable for real-time implementation. Future work will extend the proposed framework to include lateral tire slip, terrain compliance, and combined stability–traction phenomena under more realistic operating conditions, as well as the potential integration of physics-based models with data-driven predictive approaches for proactive rollover prevention.
Author Contributions
The investigation was led and supervised by E.C. and J.F. The experimental works, data acquisition, and data processing were completed by B.P., J.F., G.R. and E.C. Also, the experimental prototype and experimental tests set up were supported by M.T. and O.C. The formation and expertise of 20Sim & BG and the BG model adjustments used were completed by G.F., E.C. and B.P. The manuscript was finalized by G.R., B.P., E.C., J.F. and P.R. is the expertise consultant. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
Dataset available on request from the authors.
Acknowledgments
We thank the AUSA company, which provided the telehandler prototype and expertise used in this research. Also, Jaume Bonastre Romera of CATMech, UPC, for his valuable help.
Conflicts of Interest
Author Pedro Roquet was employed by Roquet Hydraulics S.L. company. Manel Tirado and Oriol Casadesús were employed by AUSA S.L. company. The remaining authors declare that the research was conducted in the absence of any commercial or financial relationships that could be construed as a potential conflict of interest.
Appendix A. Derivation of the Total Rotation []
To construct the complete transformation between the coordinate systems, we proceed in two steps. First, we apply an elementary rotation around the y-axis by an angle α, which tilts the original z-axis onto the unit vector
Second, we perform a rotation of angle β around this axis n.
The computation uses the Standard Rodrigues formula for rotations about an arbitrary unit vector. The standard Rodrigues expression for rotation of angle β around a unit vector n is:
The skew-symmetric matrix associated with ,,) is:
For our specific axis
we also introduce the shorthand:
Term-by-term expansion. The three components os Rodrigues’ formula are:
- (i)
- The scaled identity
- (ii)
- The axis dyadic
- (iii)
- The skew-symmetric term
- 1.
- Explicit expression ofSumming the three contributions yields
- 2.
- Elementary rotation around the y-axis.The rotation of angle α around the y-axis is:
- 3.
- Computation of the total transformation.Carrying out the matrix product and using the identityAll nonlinear terms camcel cleanly, and the result simplifies to:
Appendix B. Determination of the Global Centre of Gravity of Telehandler Using the Dual Weighing Method
This annex describes the procedure used to determine the position of the centre of gravity (CG) of a telehandler by means of the so-called dual weighing method. As mencioned, the process was not carried out with a physical platform and a real telehandler, but rather within a Virtual Tilt-Rotary Test Platform. This process follows a logic similar to that described in ISO 10392:2011 [36] and ISO 19380:2019 [37].
The method involves positioning a telehandler on a flat horizontal platform or an inclinable platform. Initial measurements are taken with the vehicle in the horizontal position, recording the vertical reactions at each front and rear wheel, both left and right. The same measurements are then repeated with the vehicle inclined forward at a known angle using a tilting platform. In both cases, the front and rear axle loads, as well as the total vehicle weight, are recorded.
A coordinate system is established where the longitudinal axis (x) runs from the rear to the front axle, the transverse axis (y) extends from right to left, and the vertical axis (z) points upward. The origin can be set at the rear axle, at the geometric centre of the vehicle, or at ground level, depending on the desired reference.
The longitudinal position of the centre of gravity is derived from the front-to-rear weight distribution measured with the vehicle on level ground. Specifically, the X-coordinate of the CG is given by the proportion of the front axle load relative to the total weight, multiplied by the wheelbase length (L). The corresponding expression is:
where is the front axle load in the horizontal position, is the total vehicle weight, and b is the wheelbase.
The transverse position of the CG is obtained by evaluating the difference in vertical reactions between the left and right wheels. By computing the net moment about the longitudinal axis, the lateral offset is expressed as a fraction of the track width (T). The formula is:
where T is the average track width, and RFL, RFR, RRL, RRR are the vertical reactions at the front-left, front-right, rear-left, and rear-right wheels, respectively.
The vertical position of the CG is calculated from the change in front axle load observed when tilting the vehicle. This difference, caused by the shift in the CG relative to the new gravity vector, is converted into a vertical height using the tangent of the inclination angle. The formula is:
where θ is the inclination angle (in radians), is the front axle load in the tilted position, and the other parameters are as defined above. It is important to note that this result yields the vertical distance of the CG relative to the rear axle or to the inclined plane, depending on the coordinate origin. If the vertical position with respect to the ground is required, it is necessary to add the vertical offset of the rear axle from the ground in the horizontal configuration, which includes the wheel radius and any structural components.
References
- Bietresato, M.; Mazzetto, F. Stability tests of agricultural and operating machines by means of an installation composed of a rotating platform (turntable) with four weighting quadrants. Appl. Sci. 2020, 10, 3786. [Google Scholar] [CrossRef] [Scilit]
- Puras, B.; Raush, G.; Freire, J.; Filippini, G.; Roquet, P.; Tirado, M.; Casadesús, O.; Codina, E. Development of a virtual telehandler model using a bond graph. Machines 2024, 12, 878. [Google Scholar] [CrossRef] [Scilit]
- ISO 22915-14:2010; Industrial Trucks—Verification of Stability—Part 14: Rough-Terrain Variable-Reach Trucks. ISO: Geneva, Switzerland, 2010.
- Wang, L.; Liu, F.; Song, Z.; Ni, Y.; He, Z.; Zhai, Z.; Zhu, X.; Zhou, Q.; Song, Z.; Li, Z. Advances in tractor rollover and stability control: Implications for off-road driving safety. Comput. Electron. Agric. 2024, 226, 109483. [Google Scholar] [CrossRef] [Scilit]
- Smith, D.W.; Perumpral, J.V.; Liljedahl, J.B. The kinematics of tractors sideways overturning. Trans. ASAE 1974, 17, 1–3. [Google Scholar] [CrossRef] [Scilit]
- Guzzomi, A.L. A revised kineto-static model for Phase I tractor rollover. Biosyst. Eng. 2012, 113, 65–75. [Google Scholar] [CrossRef] [Scilit]
- Mazzetto, F.; Bietresato, M.; Vidoni, R. Development of a dynamic stability simulator for articulated and conventional tractors useful for real-time safety devices. Appl. Mech. Mater. 2013, 394, 546–553. [Google Scholar] [CrossRef] [Scilit]
- Li, Z.; Mitsuoka, M.; Inoue, E.; Okayasu, T.; Hirai, Y.; Zhu, Z. Prediction of tractor side slipping behavior using a quasi-static model. J. Fac. Agric. Kyushu Univ. 2015, 60, 215–218. [Google Scholar] [CrossRef] [Scilit]
- Franceschetti, B.; Rondelli, V.; Capacci, E. Lateral stability performance of articulated narrow-track tractors. Agronomy 2021, 11, 2512. [Google Scholar] [CrossRef] [Scilit]
- Jang, M.-K.; Hwang, S.-J.; Nam, J.-S. Simulation study for overturning and rollover characteristics of a tractor with an implement on a hard surface. Agronomy 2022, 12, 3093. [Google Scholar] [CrossRef] [Scilit]
- Hu, Z.; Sun, Z.; Wang, L.; Zhao, X.; Gao, J.; Wang, K.; Yang, M.; Li, Z. Fast stabilization response for prevention of tractor rollover using active steering: Controller parameter optimization and real-vehicle dynamic tests. Comput. Electron. Agric. 2023, 204, 107525. [Google Scholar] [CrossRef] [Scilit]
- ISO 16231-1:2013; Self-Propelled Agricultural Machinery—Assessment of Stability—Part 1: Principles. International Organization for Standardization: Geneva, Switzerland, 2013.
- ISO 16231-2:2015; Self-Propelled Agricultural Machinery—Part 2: Determination of Static Stability and Test Procedures. International Organization for Standardization: Geneva, Switzerland, 2015.
- ISO 789-6:2019; Agricultural Tractors—Test Procedures—Part 6: Centre of Gravity. International Organization for Standardization: Geneva, Switzerland, 2019.
- Yuan, Q.; Bengea, S.; Piyabongkarn, D.; Brenner, P. Dynamic Control of a Distributed Embedded Electro-Hydraulic System; SAE Technical Paper; SAE International: Warrendale, PA, USA, 2007. [Google Scholar] [CrossRef] [Scilit]
- Činkelj, J.; Kamnik, R.; Čepon, P.; Mihelj, M.; Munih, M. Closed-loop control of hydraulic telescopic handler. Autom. Constr. 2010, 19, 954–963. [Google Scholar] [CrossRef] [Scilit]
- Altare, G.; Lovuolo, F.; Nervegna, N.; Rundo, M. Coupled simulation of a telehandler forks handling hydraulics. Int. J. Fluid Power 2012, 13, 15–28. [Google Scholar] [CrossRef] [Scilit]
- Somà, A.; Bruzzese, F.; Mocera, F.; Viglietti, E. Hybridization factor and performance of hybrid electric telehandler vehicle. IEEE Trans. Ind. Appl. 2016, 52, 4831–4839. [Google Scholar] [CrossRef] [Scilit]
- Serrao, L.; Ornella, G.; Balboni, L.; Maximiliano, C.; Bort, G.; Dousy, C.; Zendri, F. A telehandler vehicle as mobile laboratory for hydraulic hybrid powertrain technology development. In Proceedings of the 10th International Fluid Power Conference, Dresden, Germany, 8–10 March 2016. [Google Scholar]
- Fassbender, D.; Brach, C.; Minav, T. Experimental investigations of partially valve-partially displacement controlled electrified telehandler implements. Actuators 2023, 12, 50. [Google Scholar] [CrossRef] [Scilit]
- Martini, V.; Mocera, F.; Somà, A. Carbon footprint enhancement of an agricultural telehandler through the application of a fuel cell powertrain. World Electr. Veh. J. 2024, 15, 91. [Google Scholar] [CrossRef] [Scilit]
- Monacelli, G.; Largo, S.; D’Aria, R. Virtual stability simulation of a telescopic handler machine according to the standard UNI EN 1459. In Proceedings of the 2013 European Altair Technology Conference, Turin, Italy, 22–24 April 2013. [Google Scholar]
- Guo, H.; Mu, X.; Du, F.; Lv, K. Lateral stability analysis of telehandlers based on multibody dynamics. WSEAS Trans. Appl. Theor. Mech. 2016, 11, 1–7. [Google Scholar]
- Rosati, G.; Biondi, A.; Boschetti, G.; Rossi, A. Real-time estimation of the telescopic handler centre of mass. In Proceedings of the 12th IFToMM World Congress, Besançon, France, 17–21 June 2007. [Google Scholar]
- Priora, G. Monitor and Control System of the Dynamic Stability on a Telescopic Handler with Telemetry and Experimental Data. Master’s Thesis, Politecnico di Torino, Turin, Italy, 2019. [Google Scholar]
- NHTSA. Rollover Resistance Rating System Using the Static Stability Factor; U.S. Department of Transportation: Washington, DC, USA, 2003. [Google Scholar]
- Liu, J.; Ayers, P.D. Off-road vehicle rollover and field testing of stability index. J. Agric. Saf. Health 1999, 5, 59–72. [Google Scholar] [CrossRef] [Scilit]
- Lee, H.S.; Kim, J.H. Machine-learning-based rollover risk prediction for heavy vehicles. Appl. Sci. 2025, 15, 4886. [Google Scholar] [CrossRef] [Scilit]
- EN 15000:2008; Safety of Industrial Trucks—Self-Propelled Variable-Reach Trucks—Specification, Performance and Test Requirements. CEN: Brussels, Belgium, 2008.
- Papadopoulos, E.G.; Rey, D.A. A new measure of tipover stability margin for mobile manipulators. In Proceedings of the IEEE International Conference on Robotics and Automation, Minneapolis, MN, USA, 22–28 April 1996. [Google Scholar]
- Sindha, J.; Chakraborty, B.; Chakravarty, D. Rigid body modeling of three-wheel vehicle to determine the dynamic stability—A practical approach. In Proceedings of the IEEE International Transportation Electrification Conference (ITEC); IEEE: New York, NY, USA, 2015. [Google Scholar] [CrossRef] [Scilit]
- Baker, V.; Guzzomi, A.L. A model and comparison of 4-wheel-drive fixed-chassis tractor rollover during Phase I. Biosyst. Eng. 2013, 116, 179–189. [Google Scholar] [CrossRef] [Scilit]
- Bietresato, M.; Mazzetto, F. A novel facility for statically testing the stability of vehicles: Technical features and possibilities. Int. J. Sustain. Dev. Plan. 2022, 6, 107–121. [Google Scholar] [CrossRef] [Scilit]
- Carabin, G.; Karaca, M.; Mazzetto, F. Preliminary results of extensive tractor rollover stability tests using a tilting-rotating rig. Biosyst. Eng. 2025, 254, 104146. [Google Scholar] [CrossRef] [Scilit]
- CEN/TS 1459-8:2018; Rough-Terrain Trucks—Safety Requirements and Verification—Part 8: Variable-Reach Trucks. CEN: Brussels, Belgium, 2018.
- ISO 10392:2011; Road Vehicles—Determination of Centre of Gravity. ISO: Geneva, Switzerland, 2011.
- ISO 19380:2019; Heavy Commercial Vehicles and Buses—Centre of Gravity Measurements. ISO: Geneva, Switzerland, 2019.
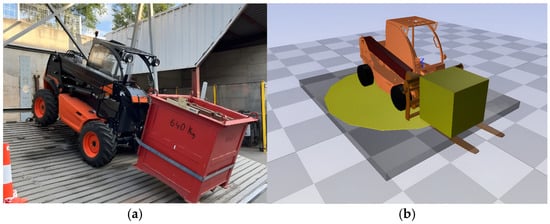
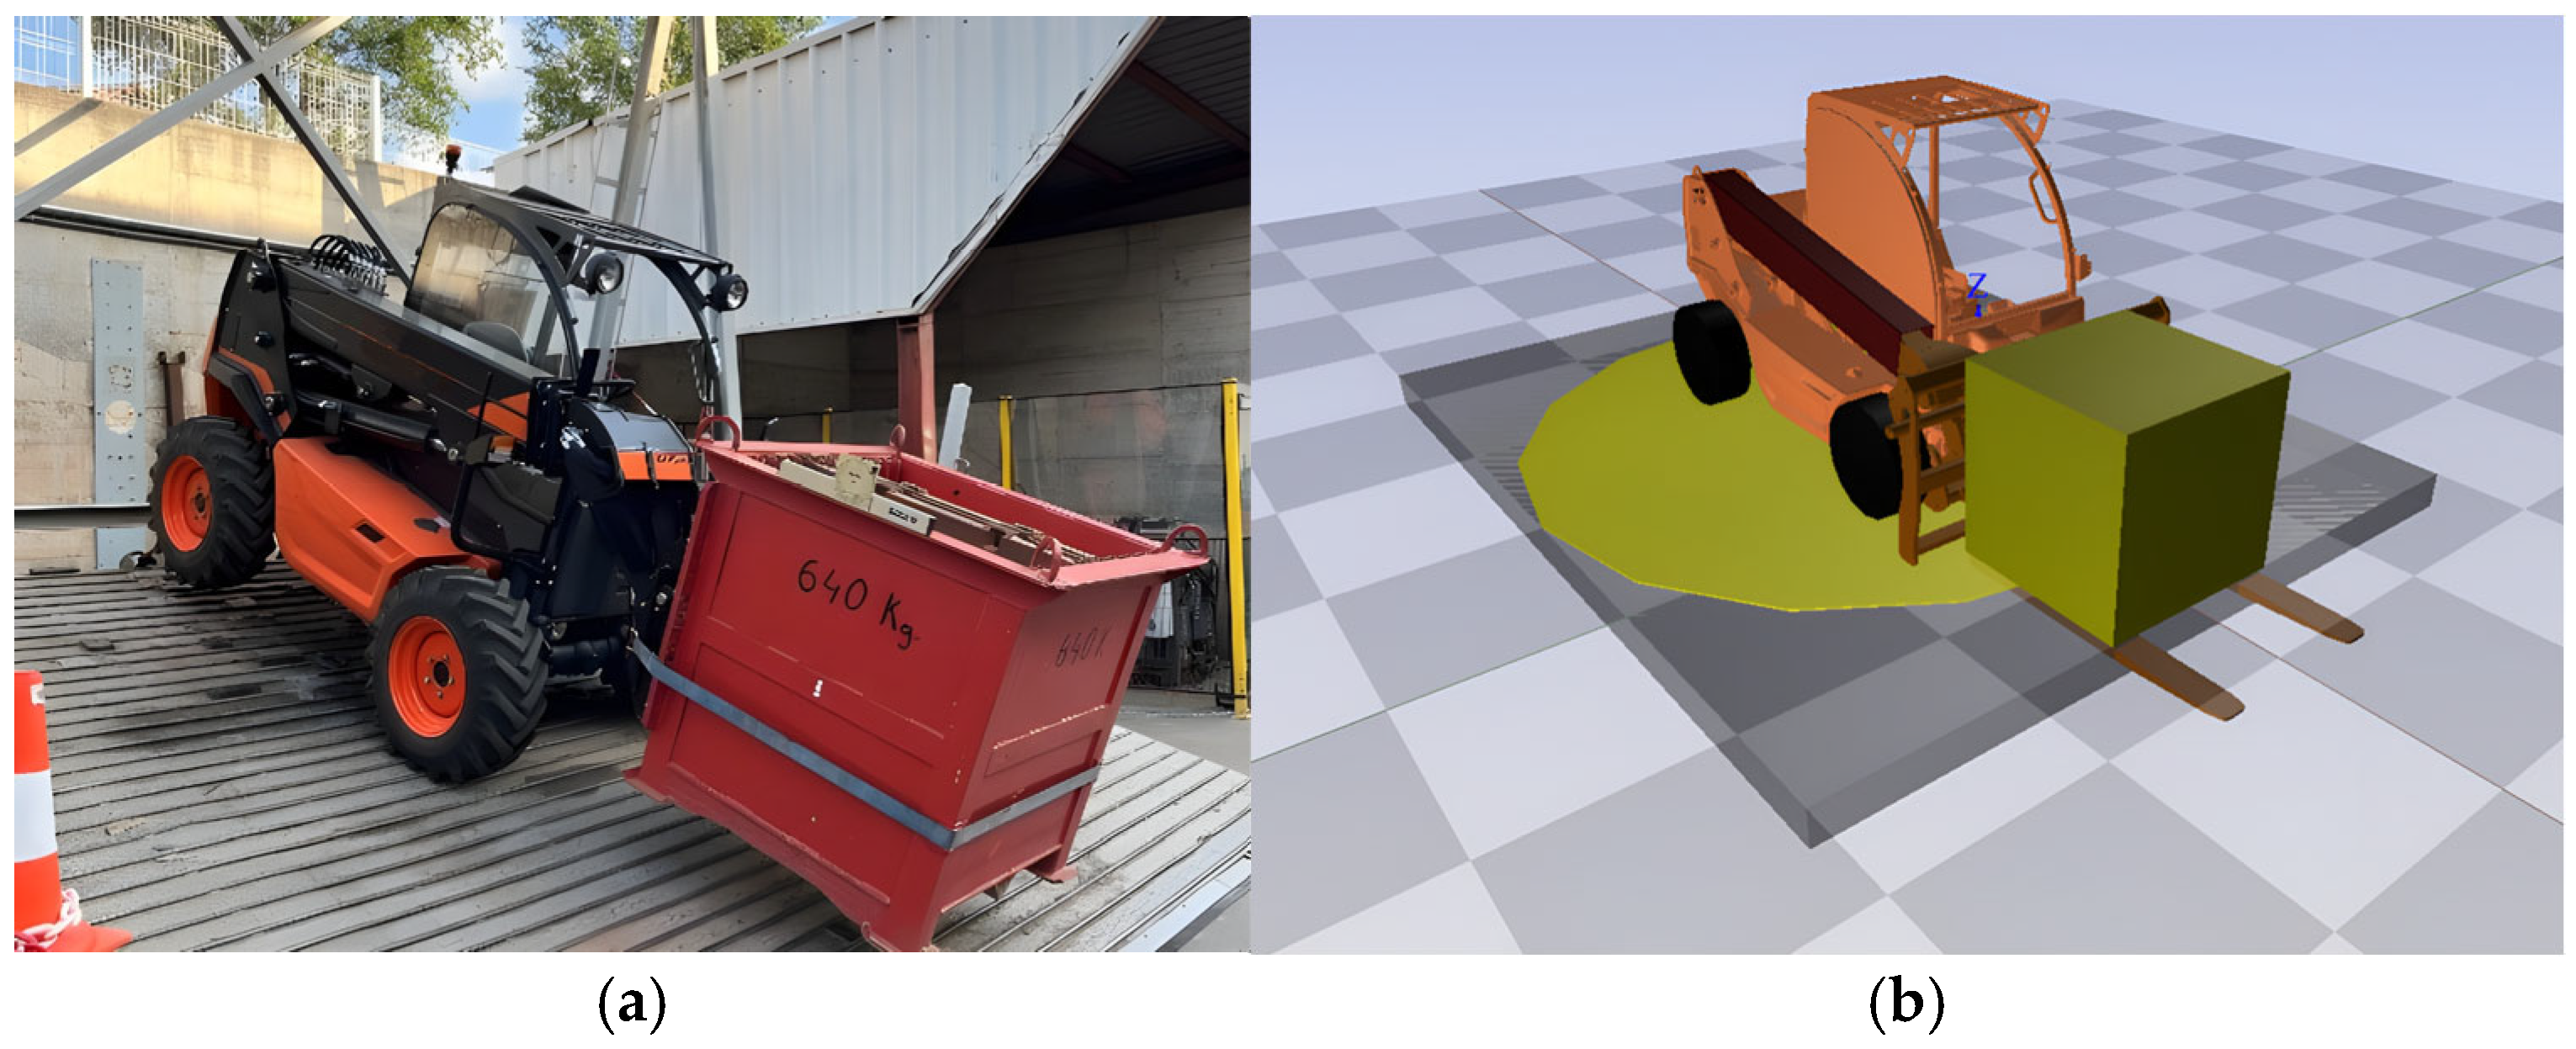
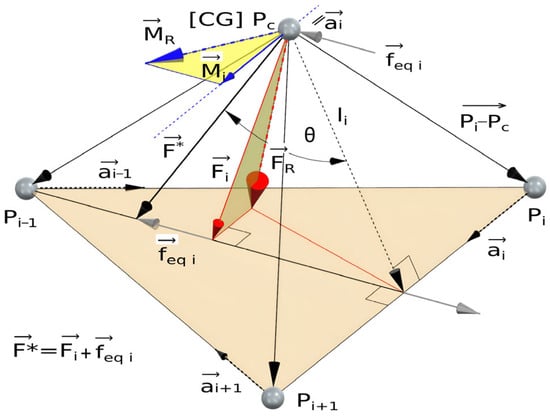
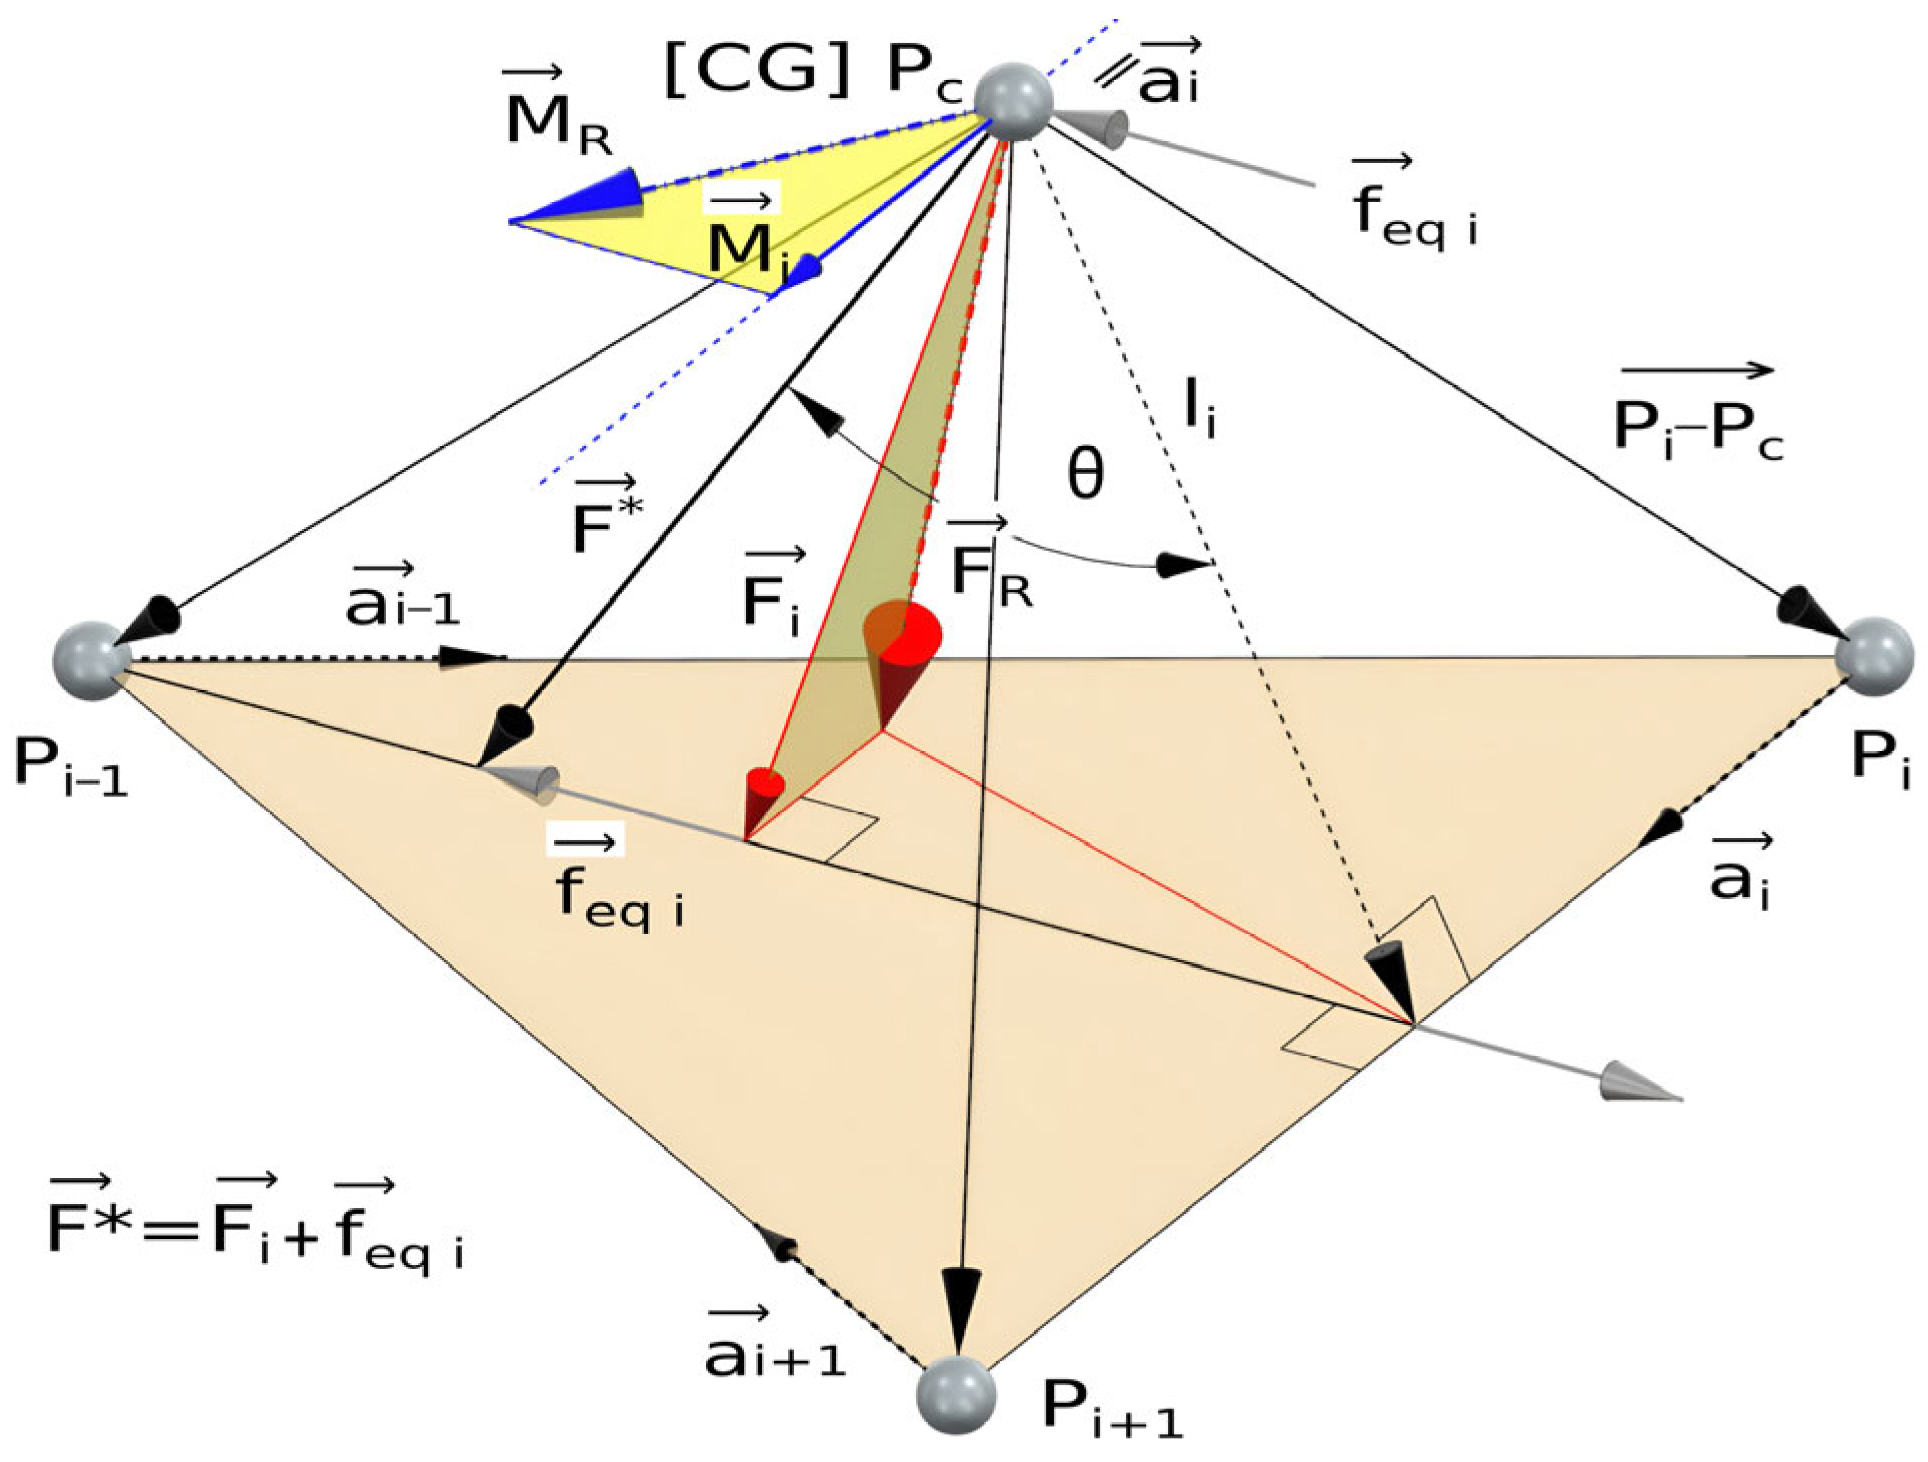
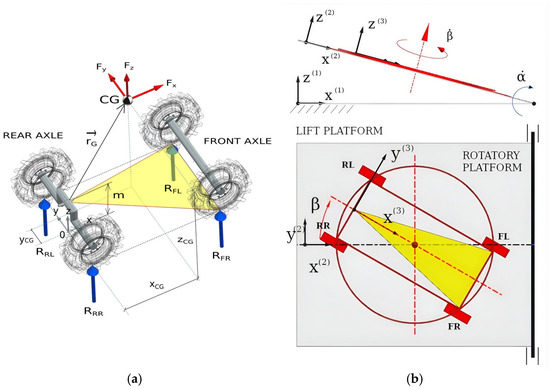
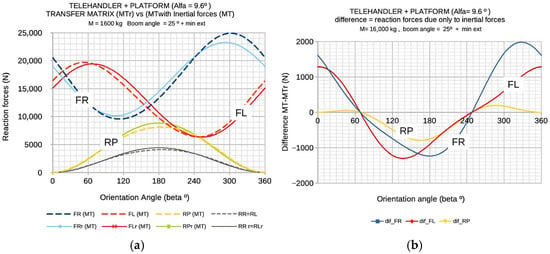
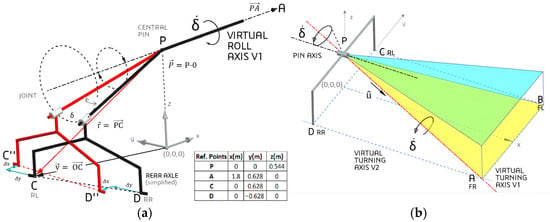
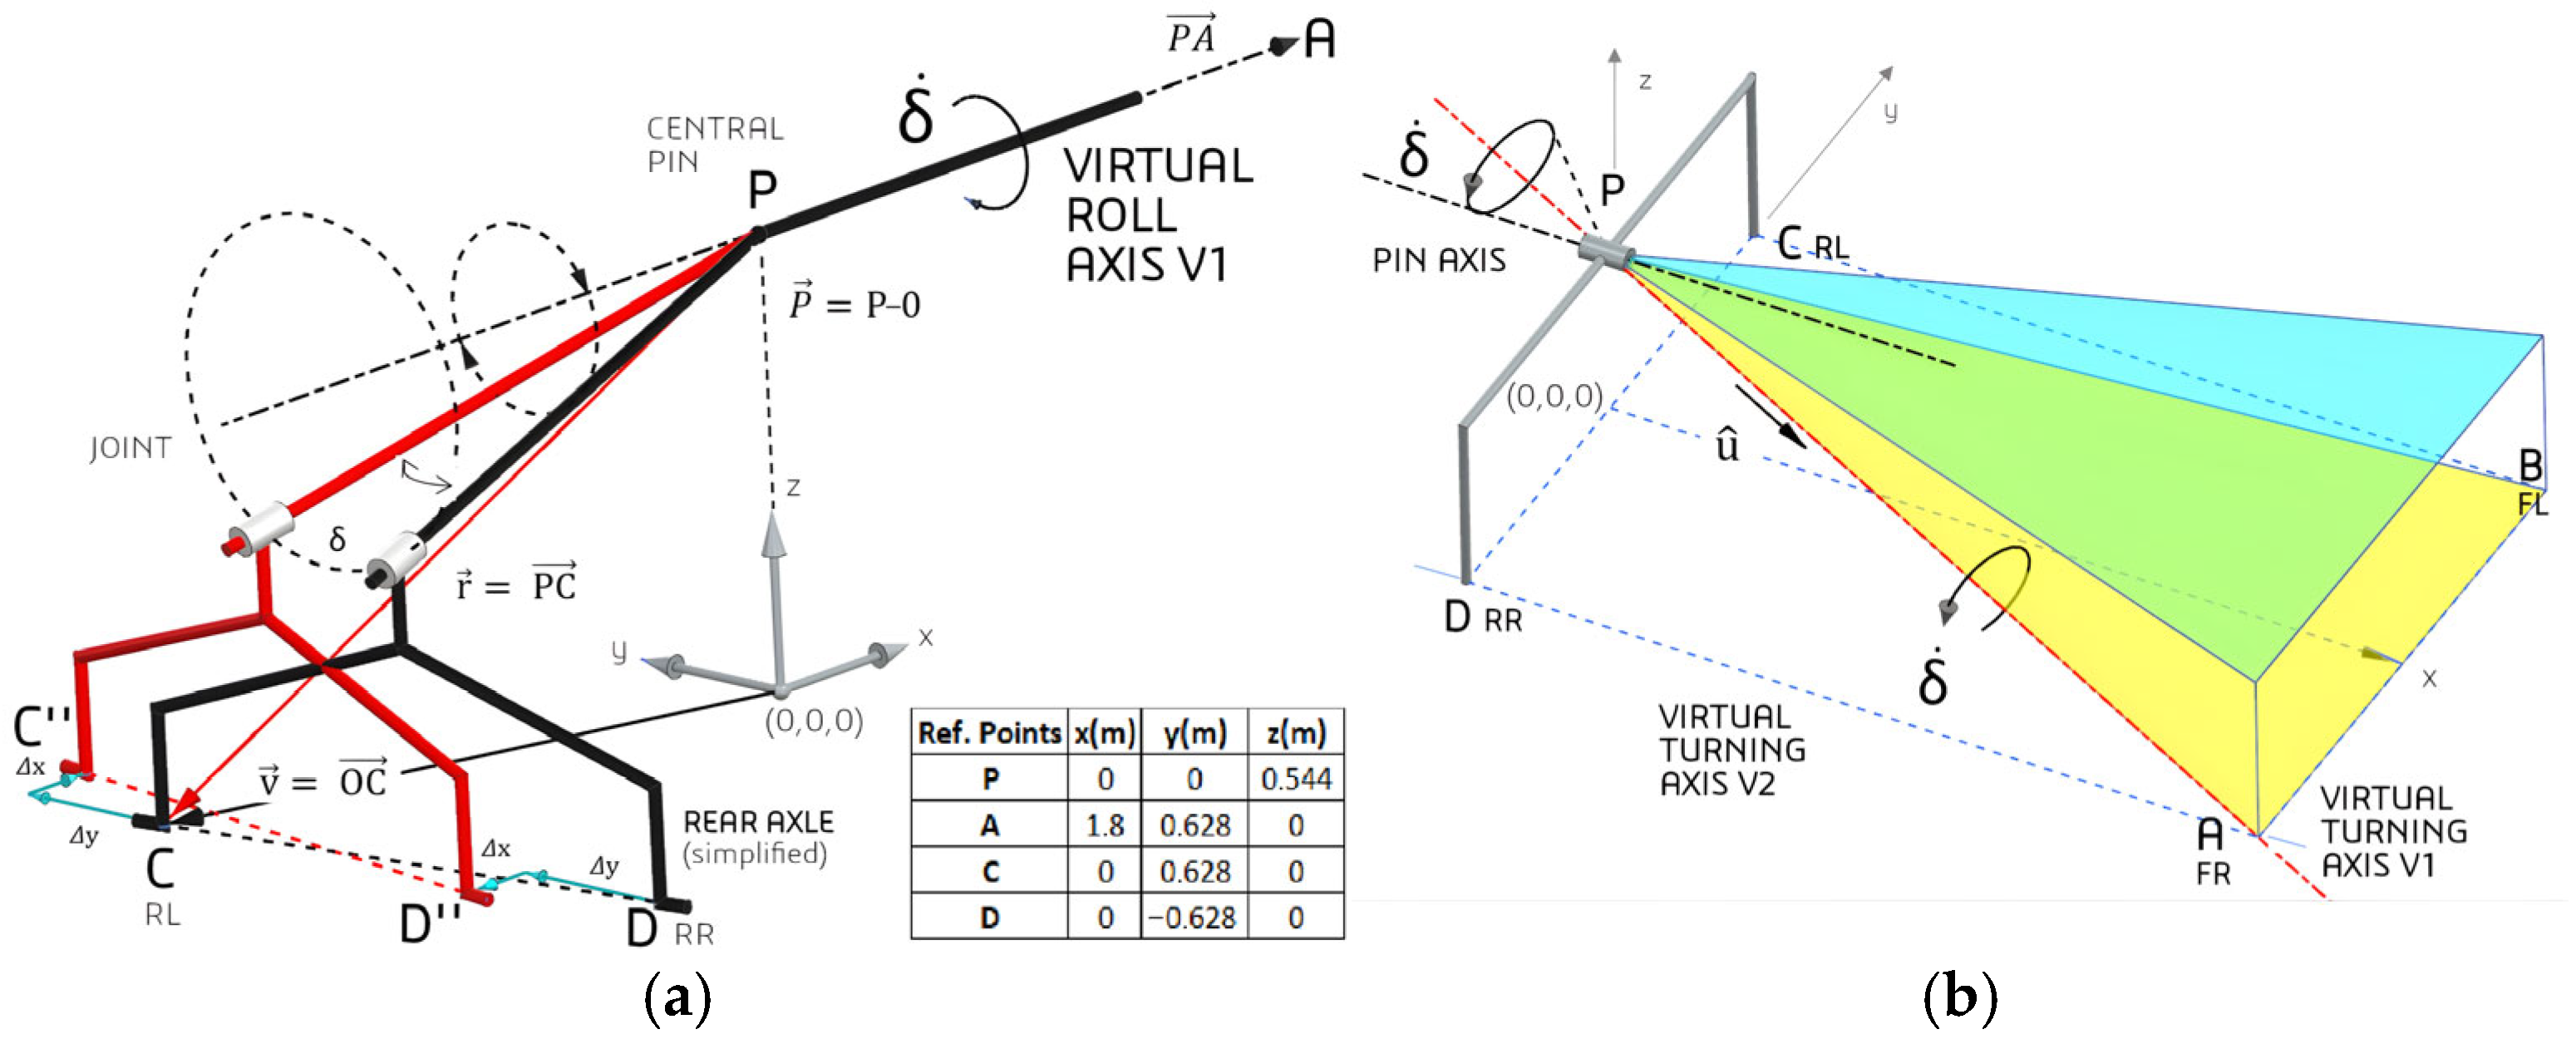
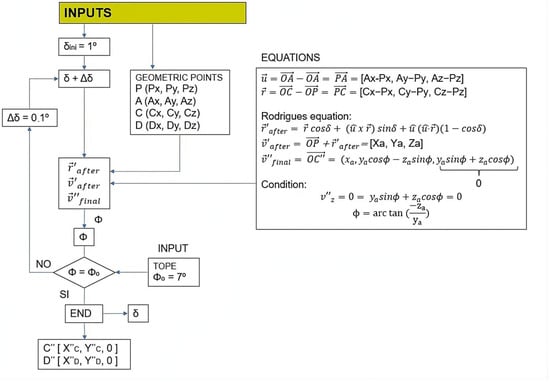
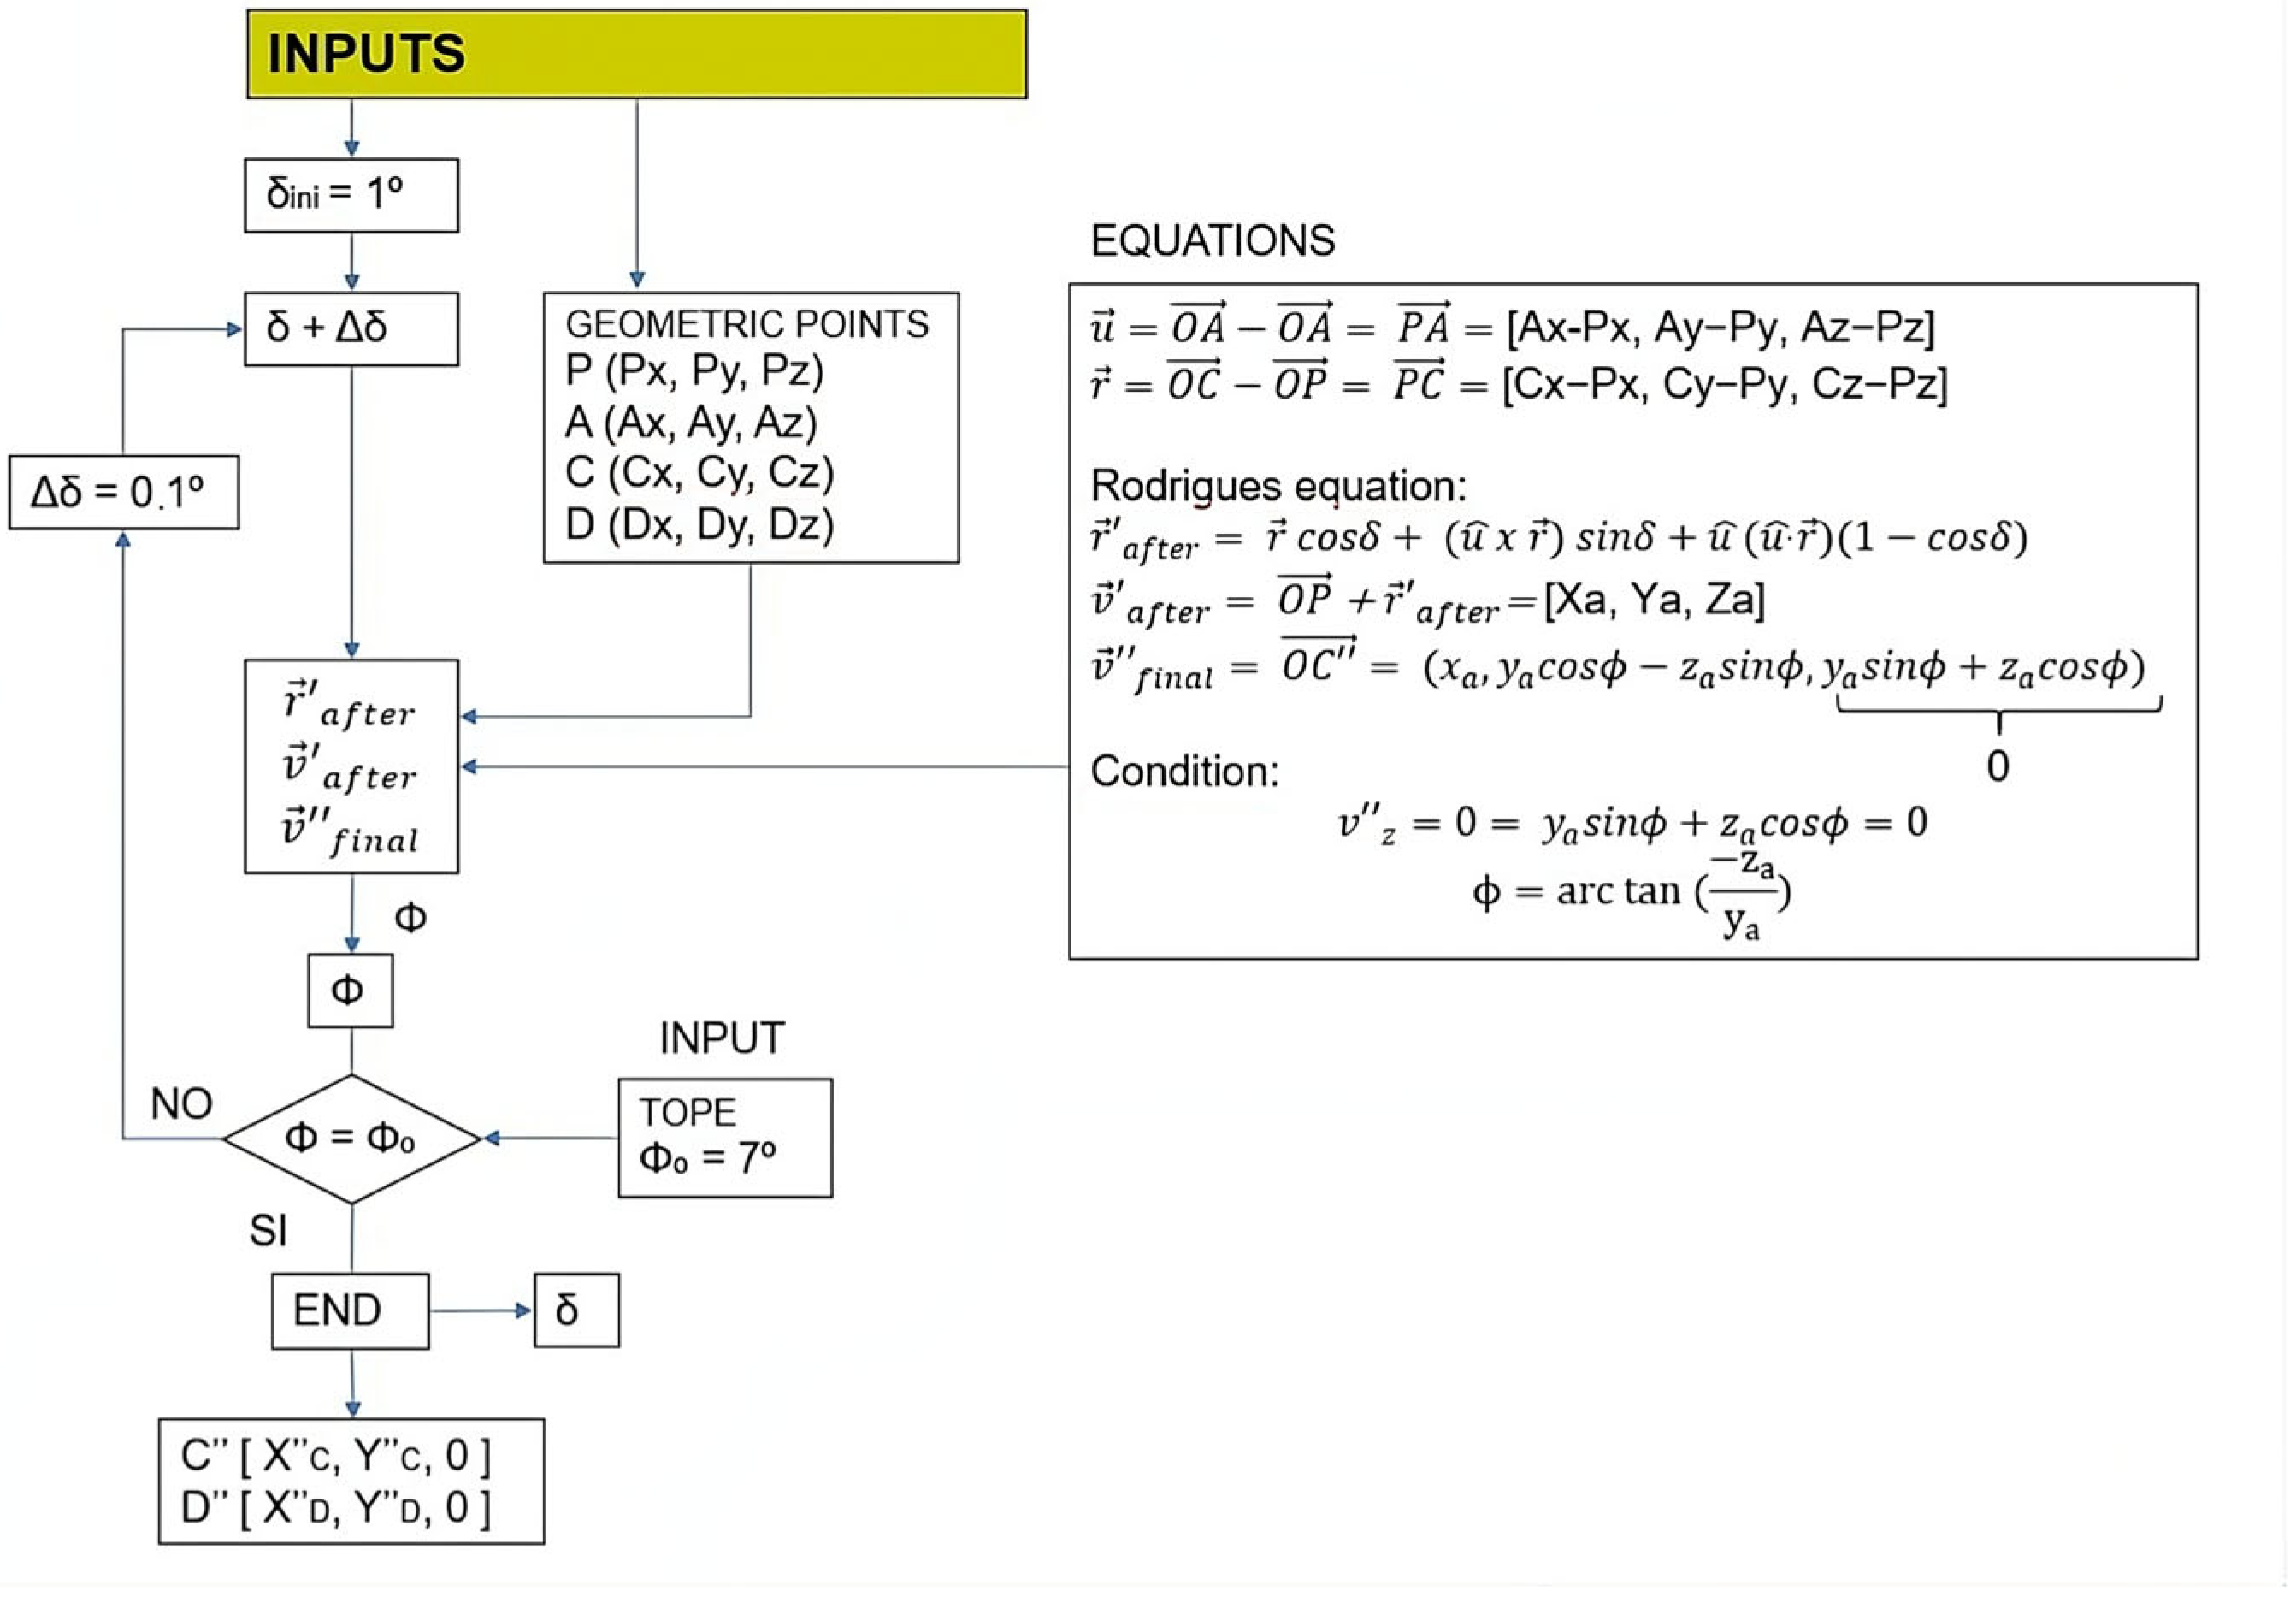
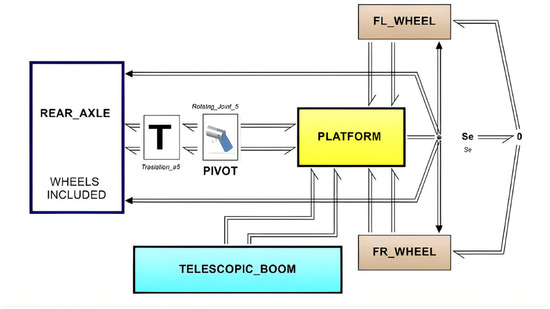
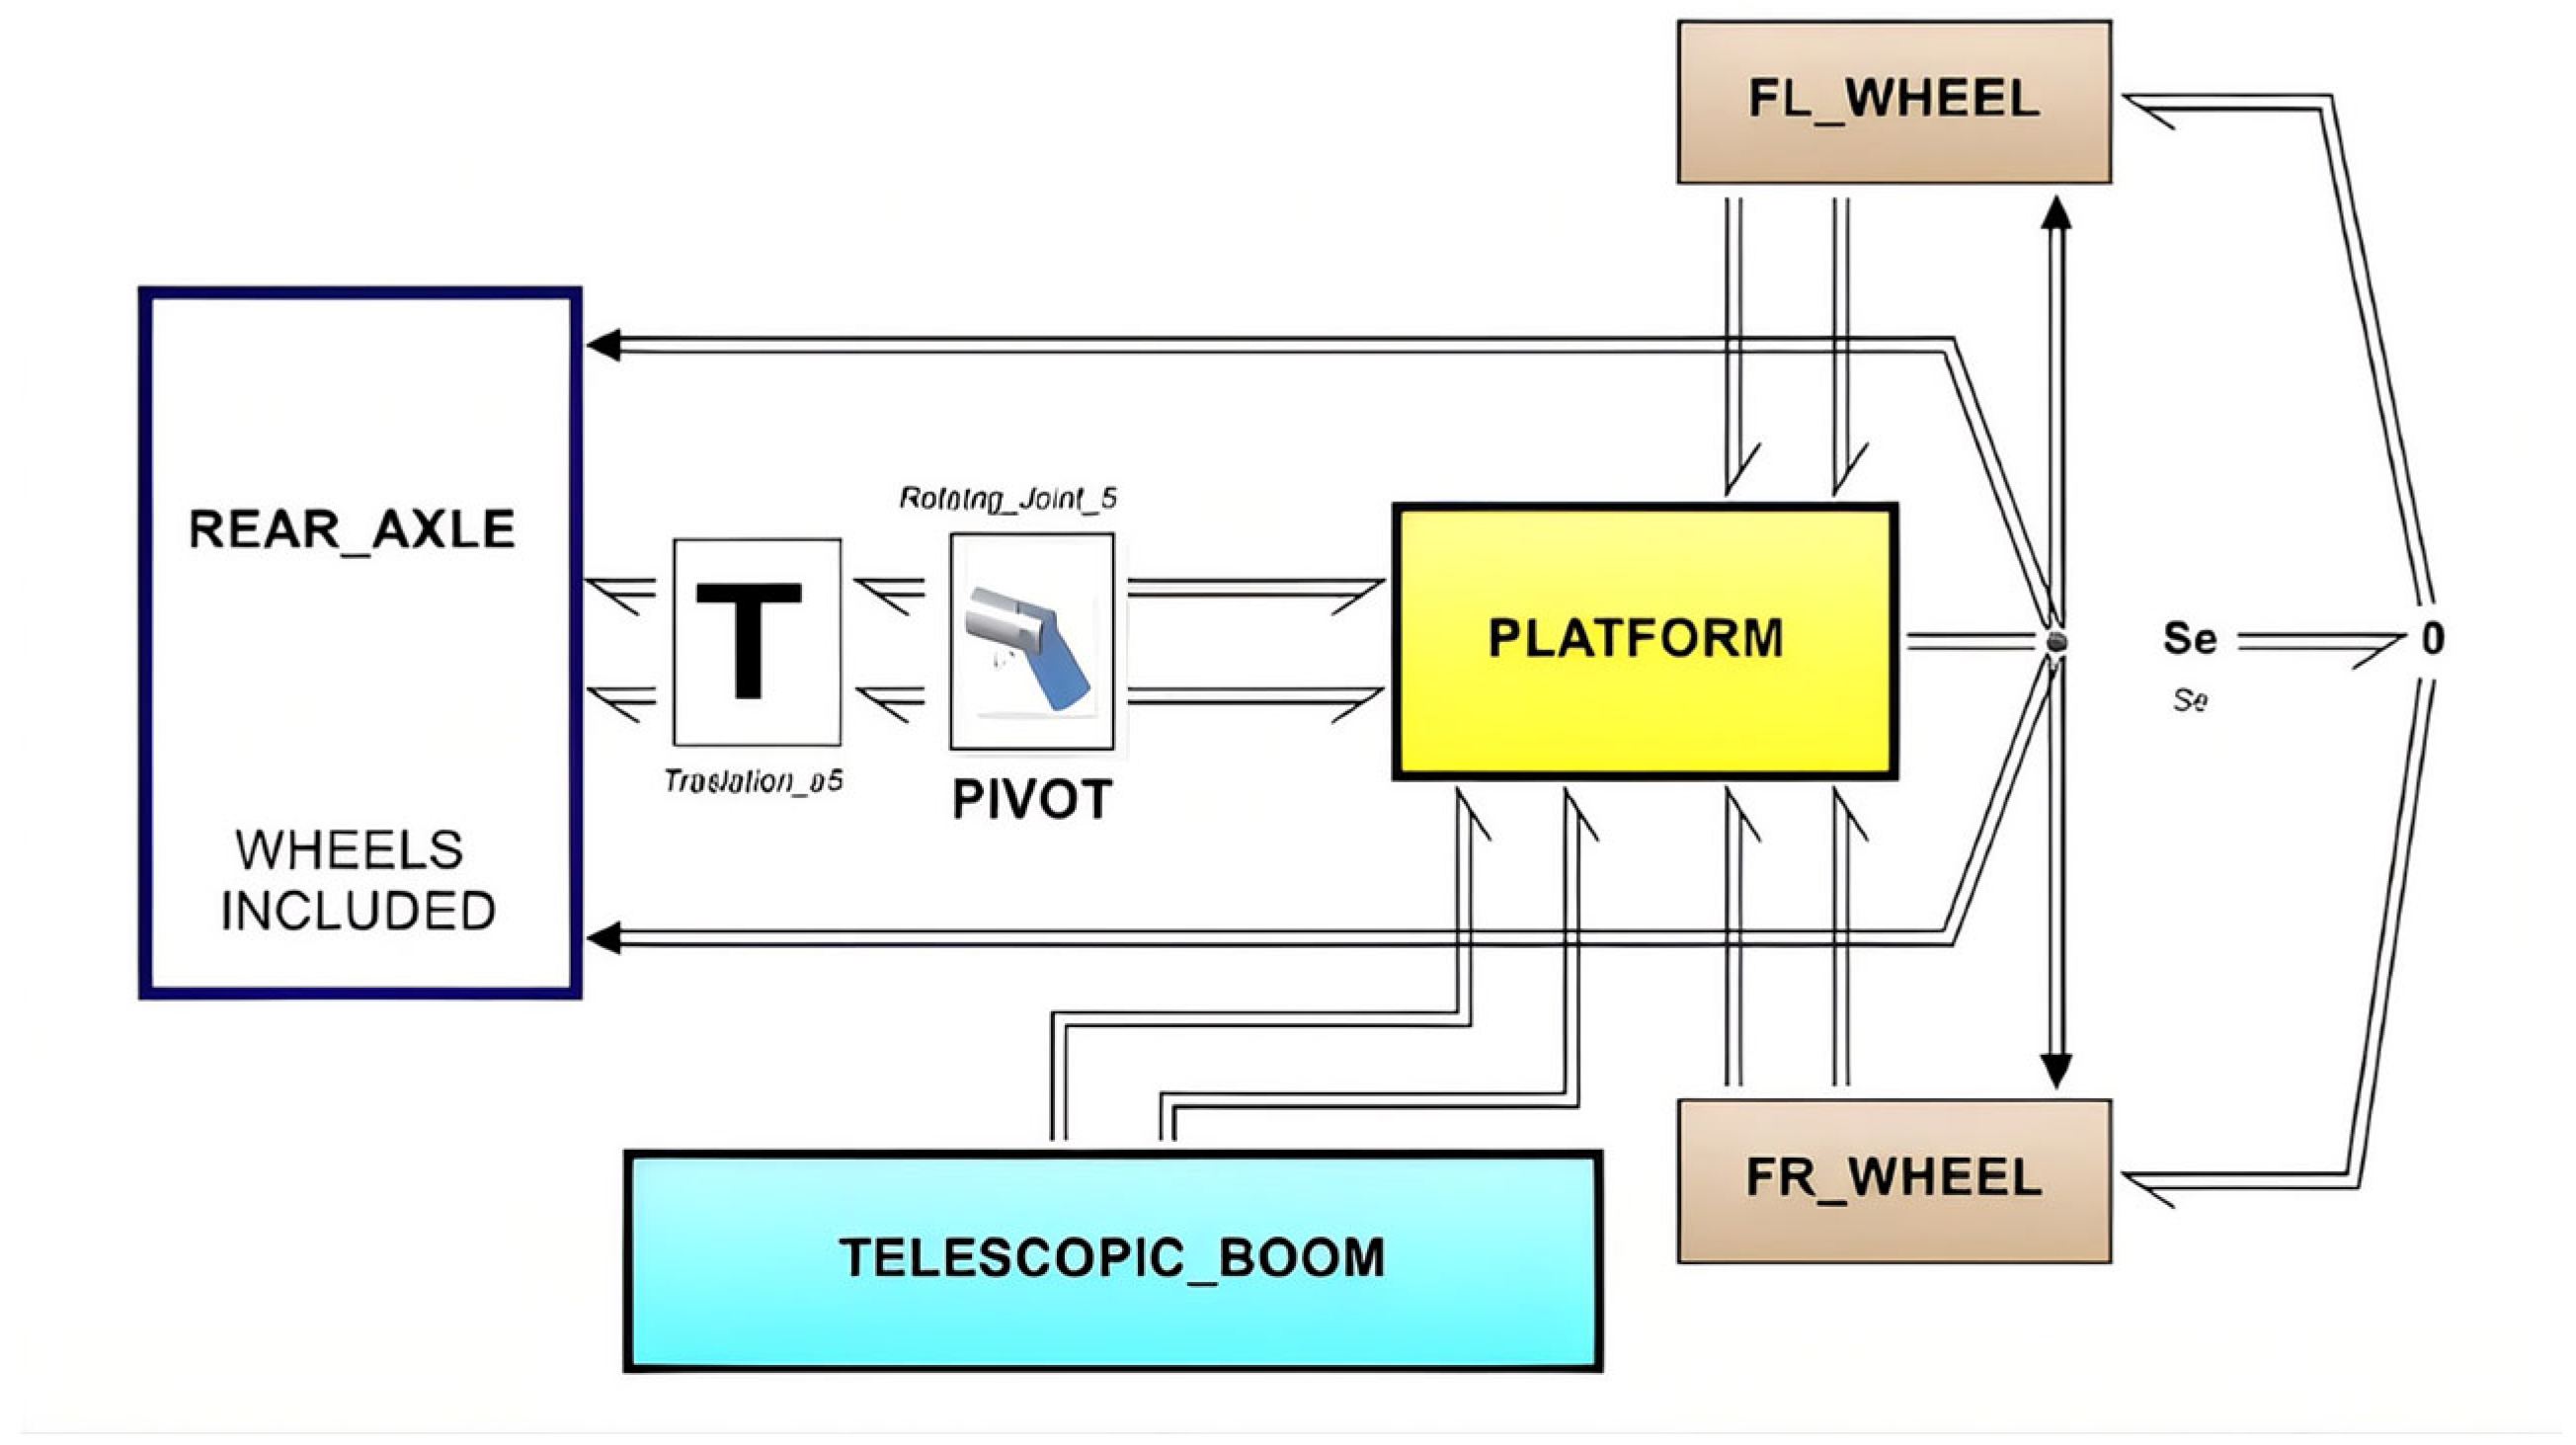
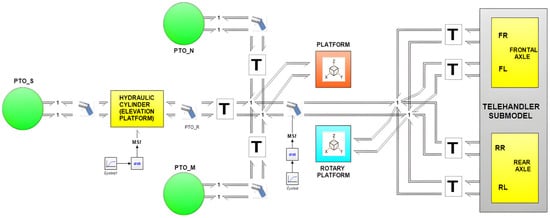
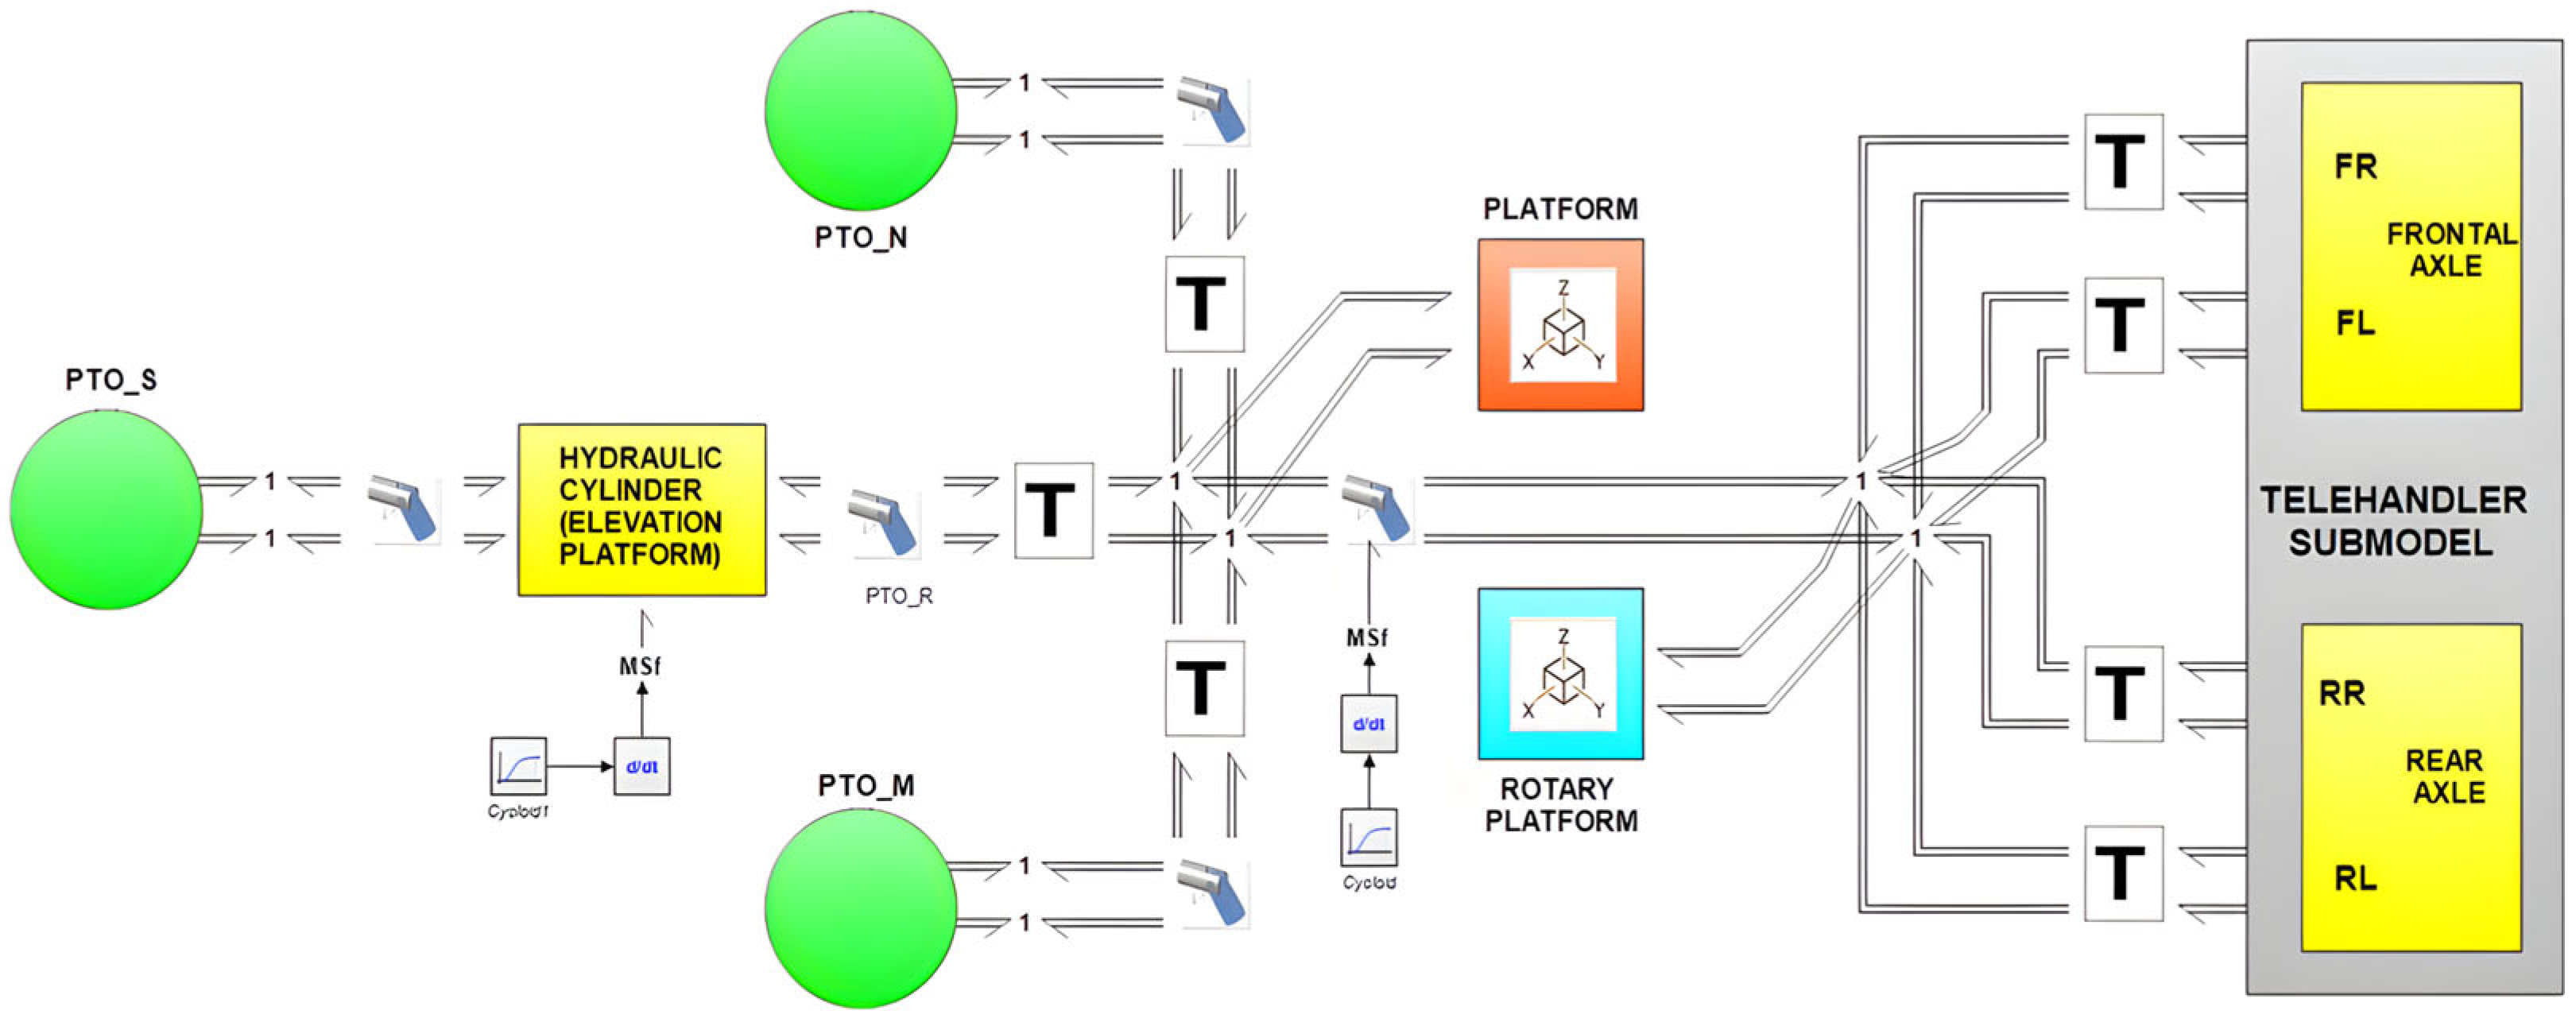
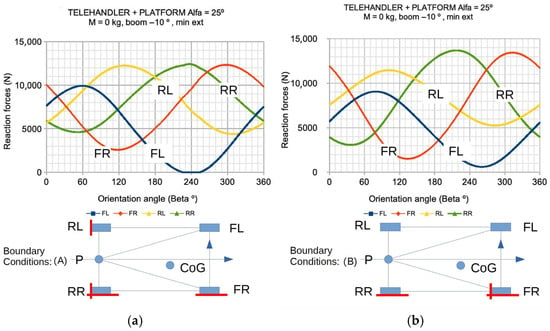
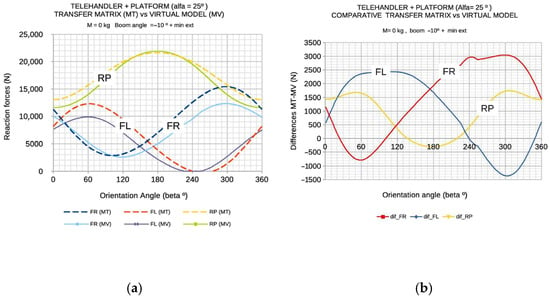
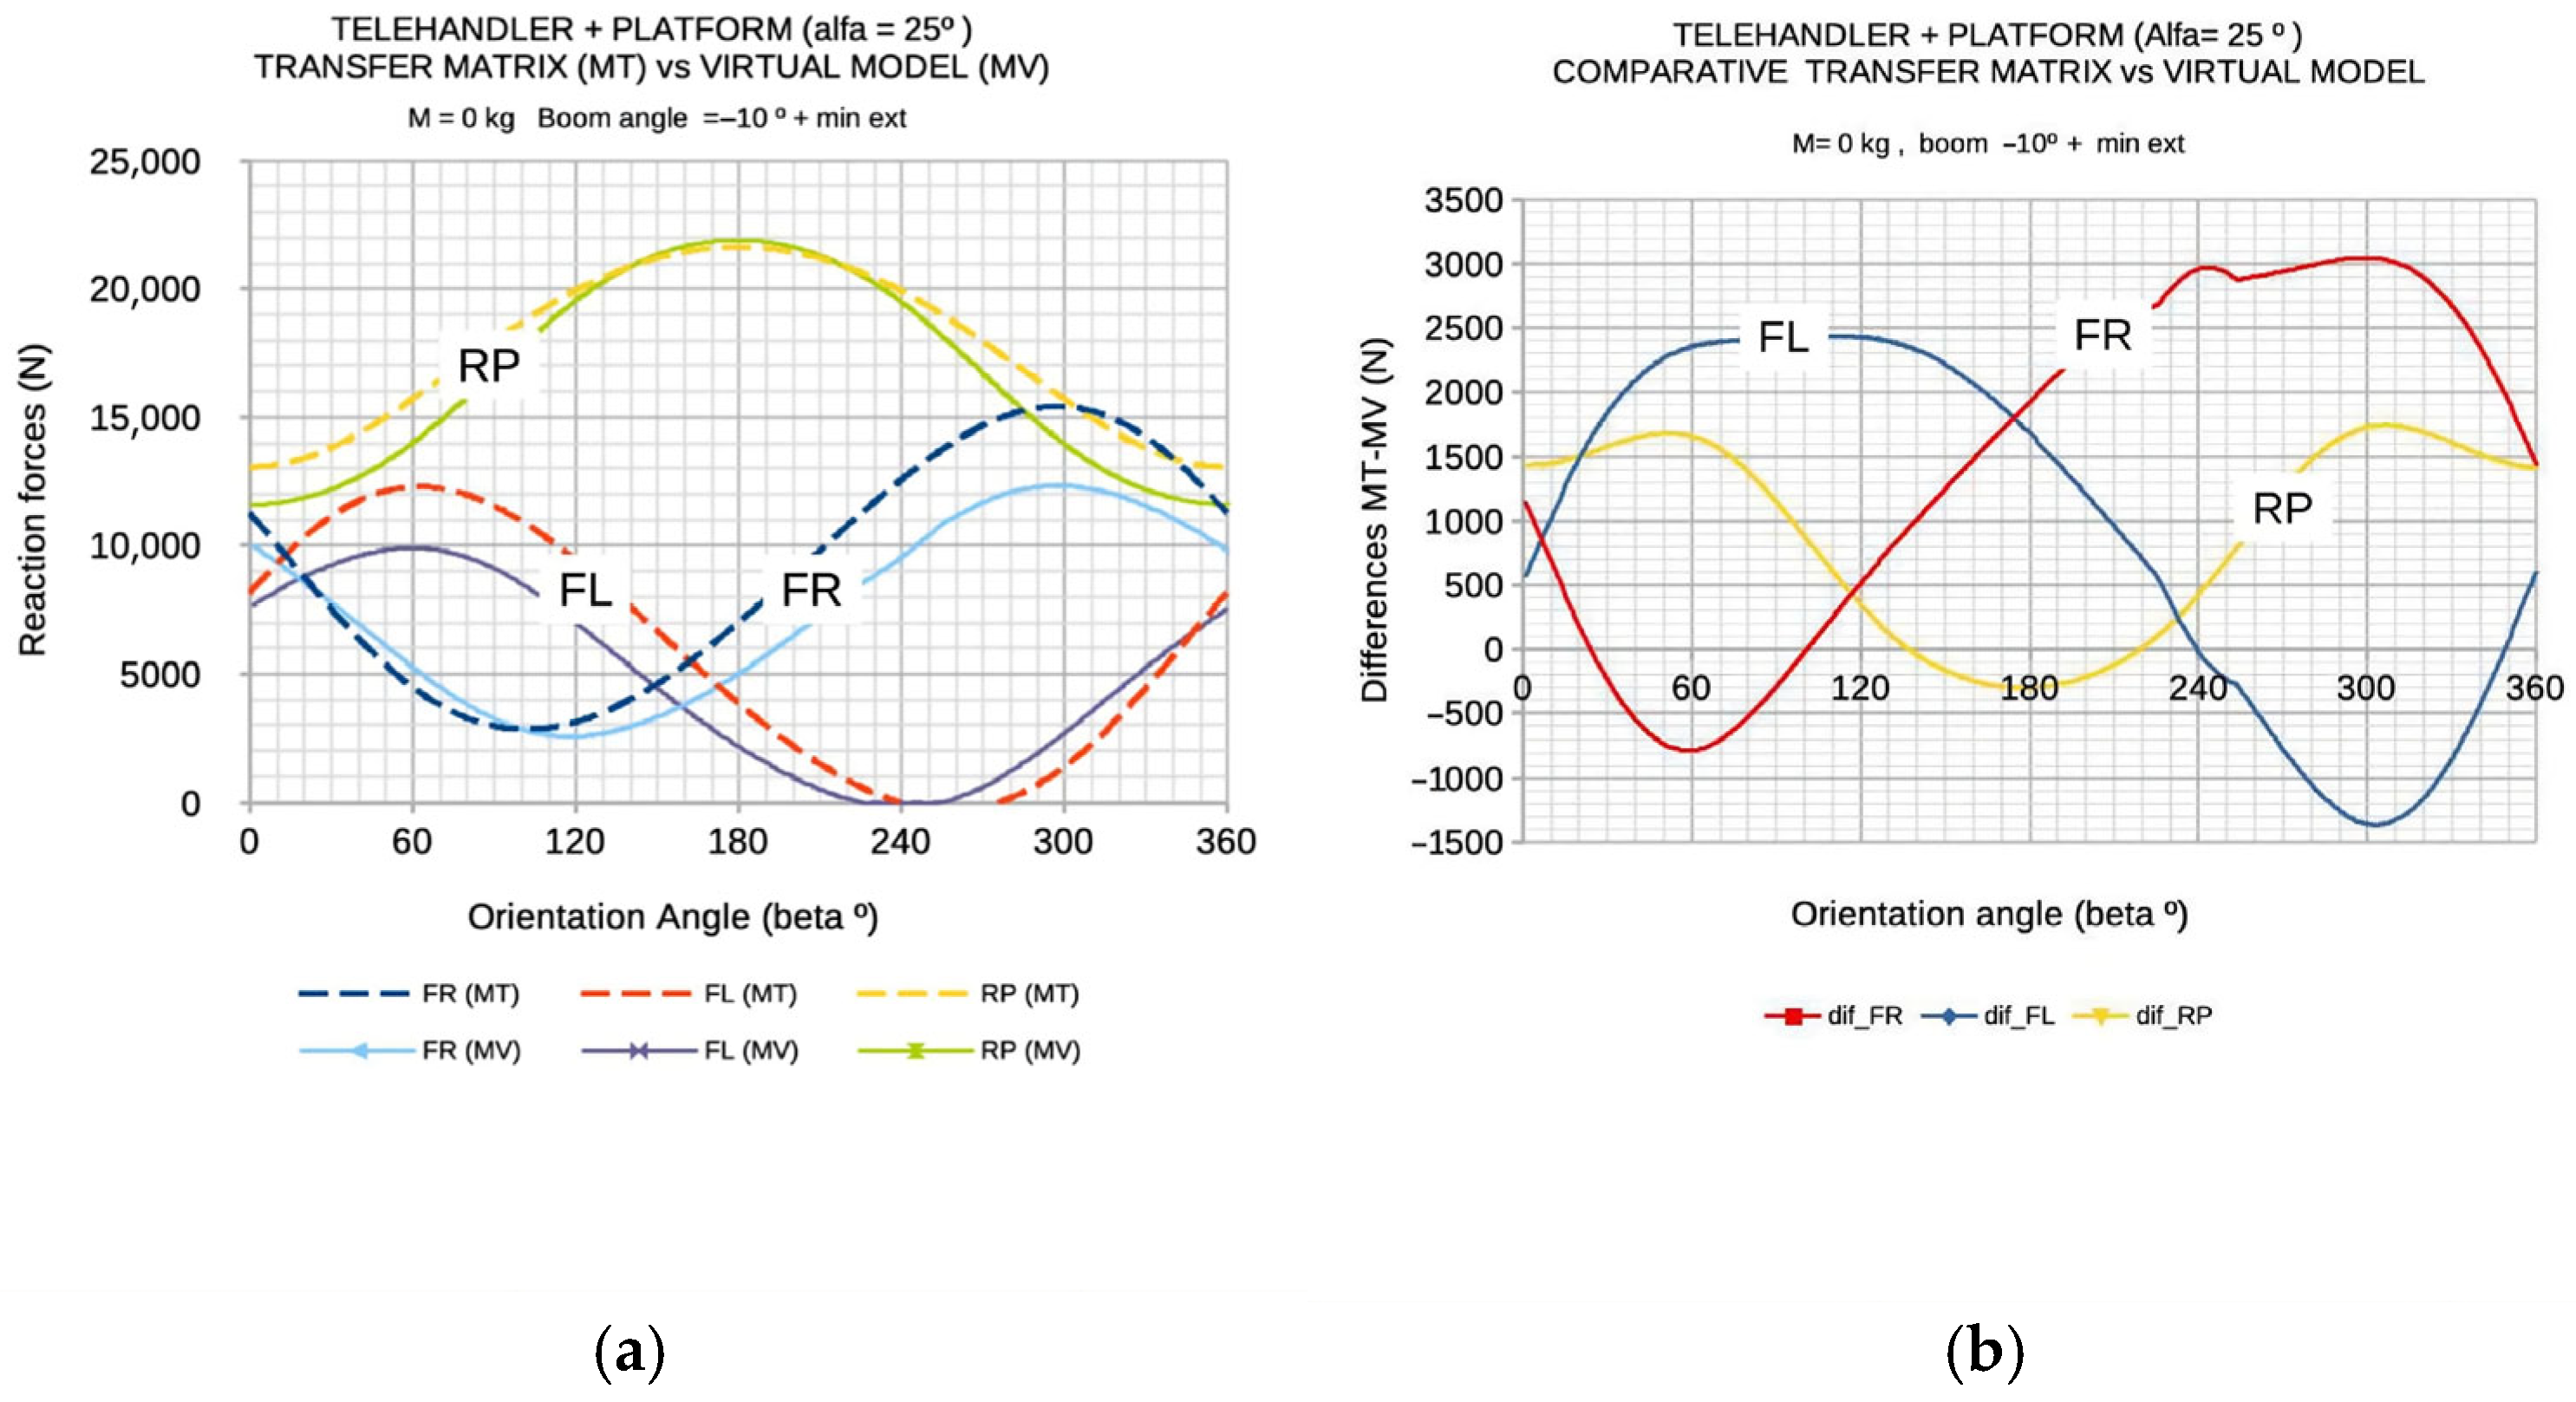
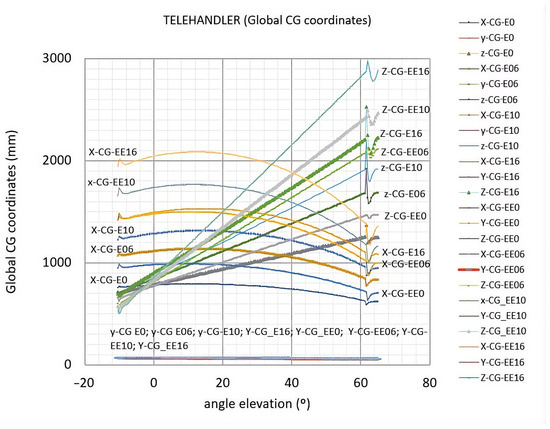
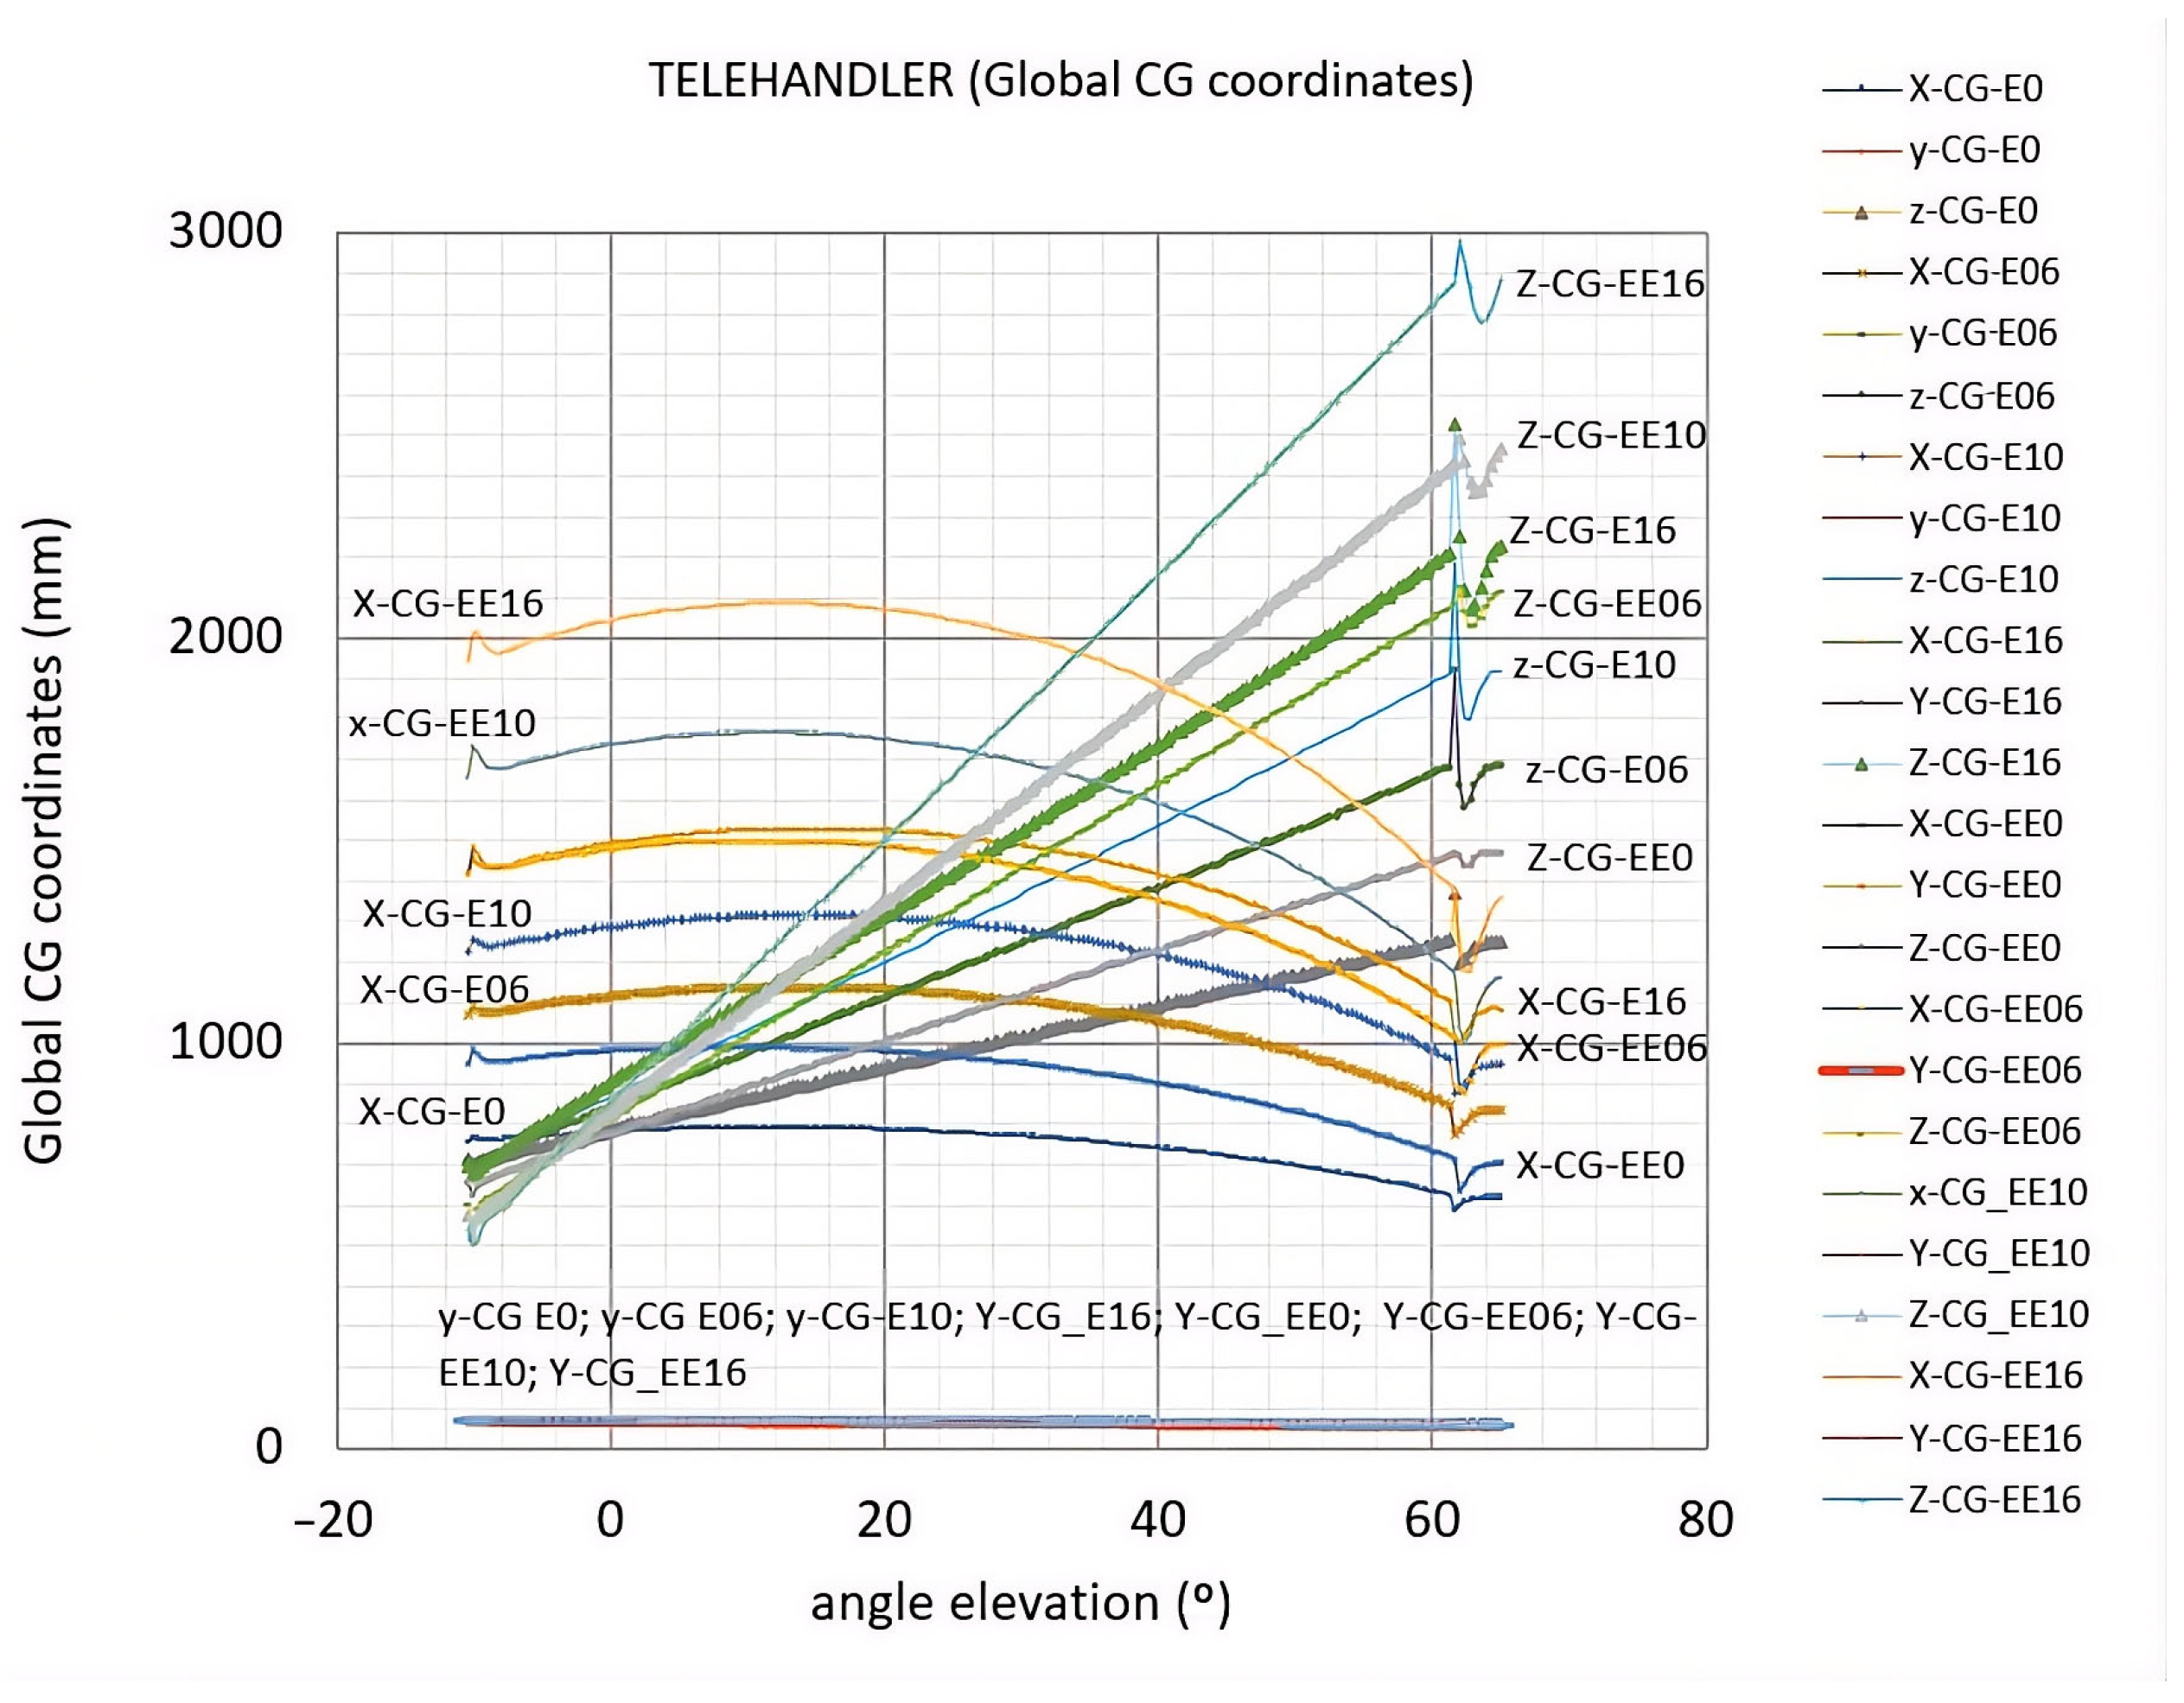
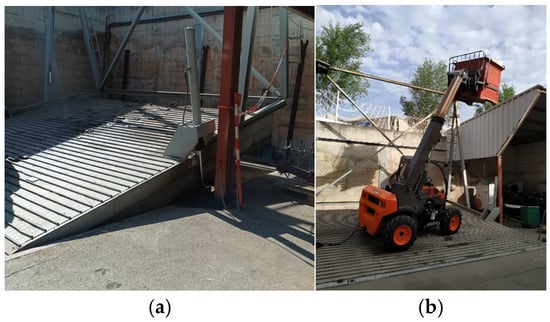
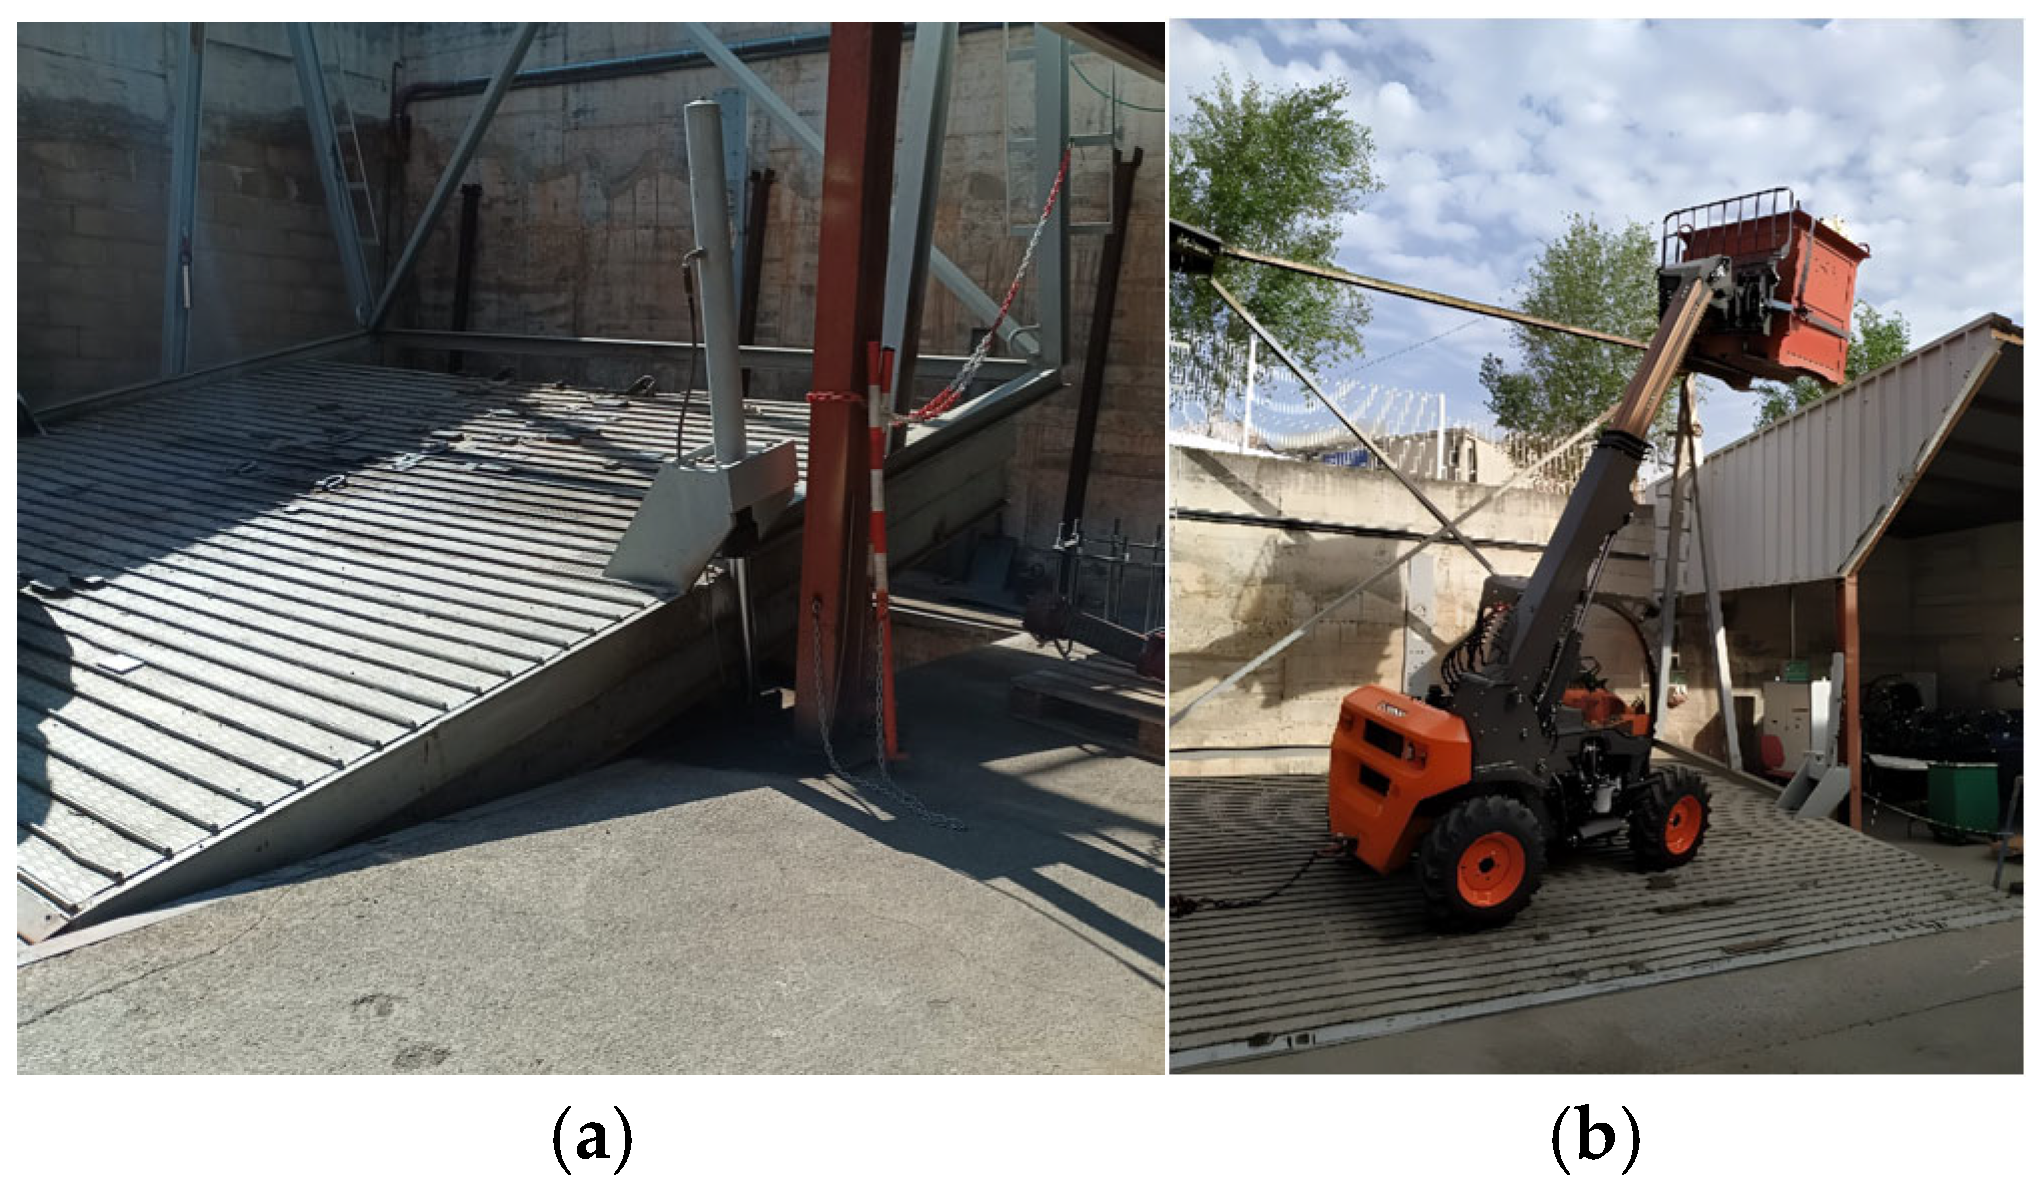
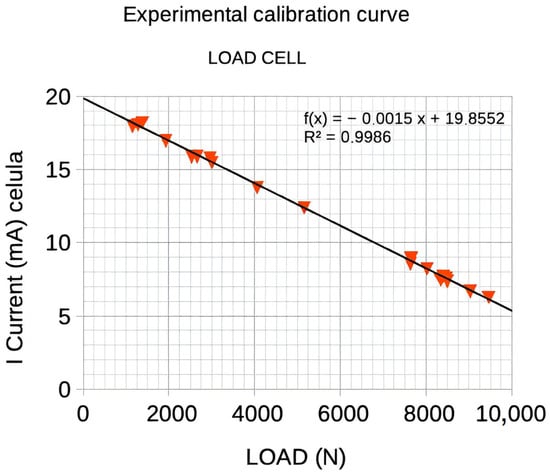
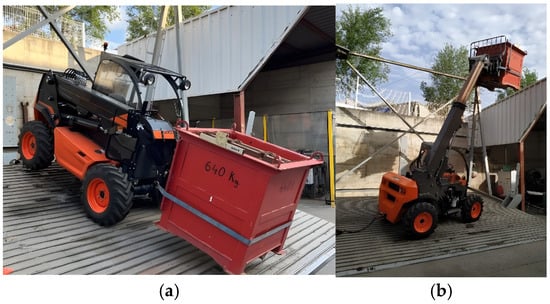
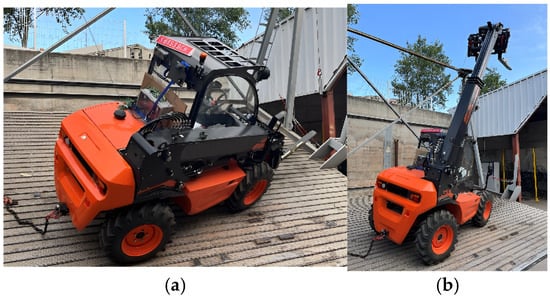
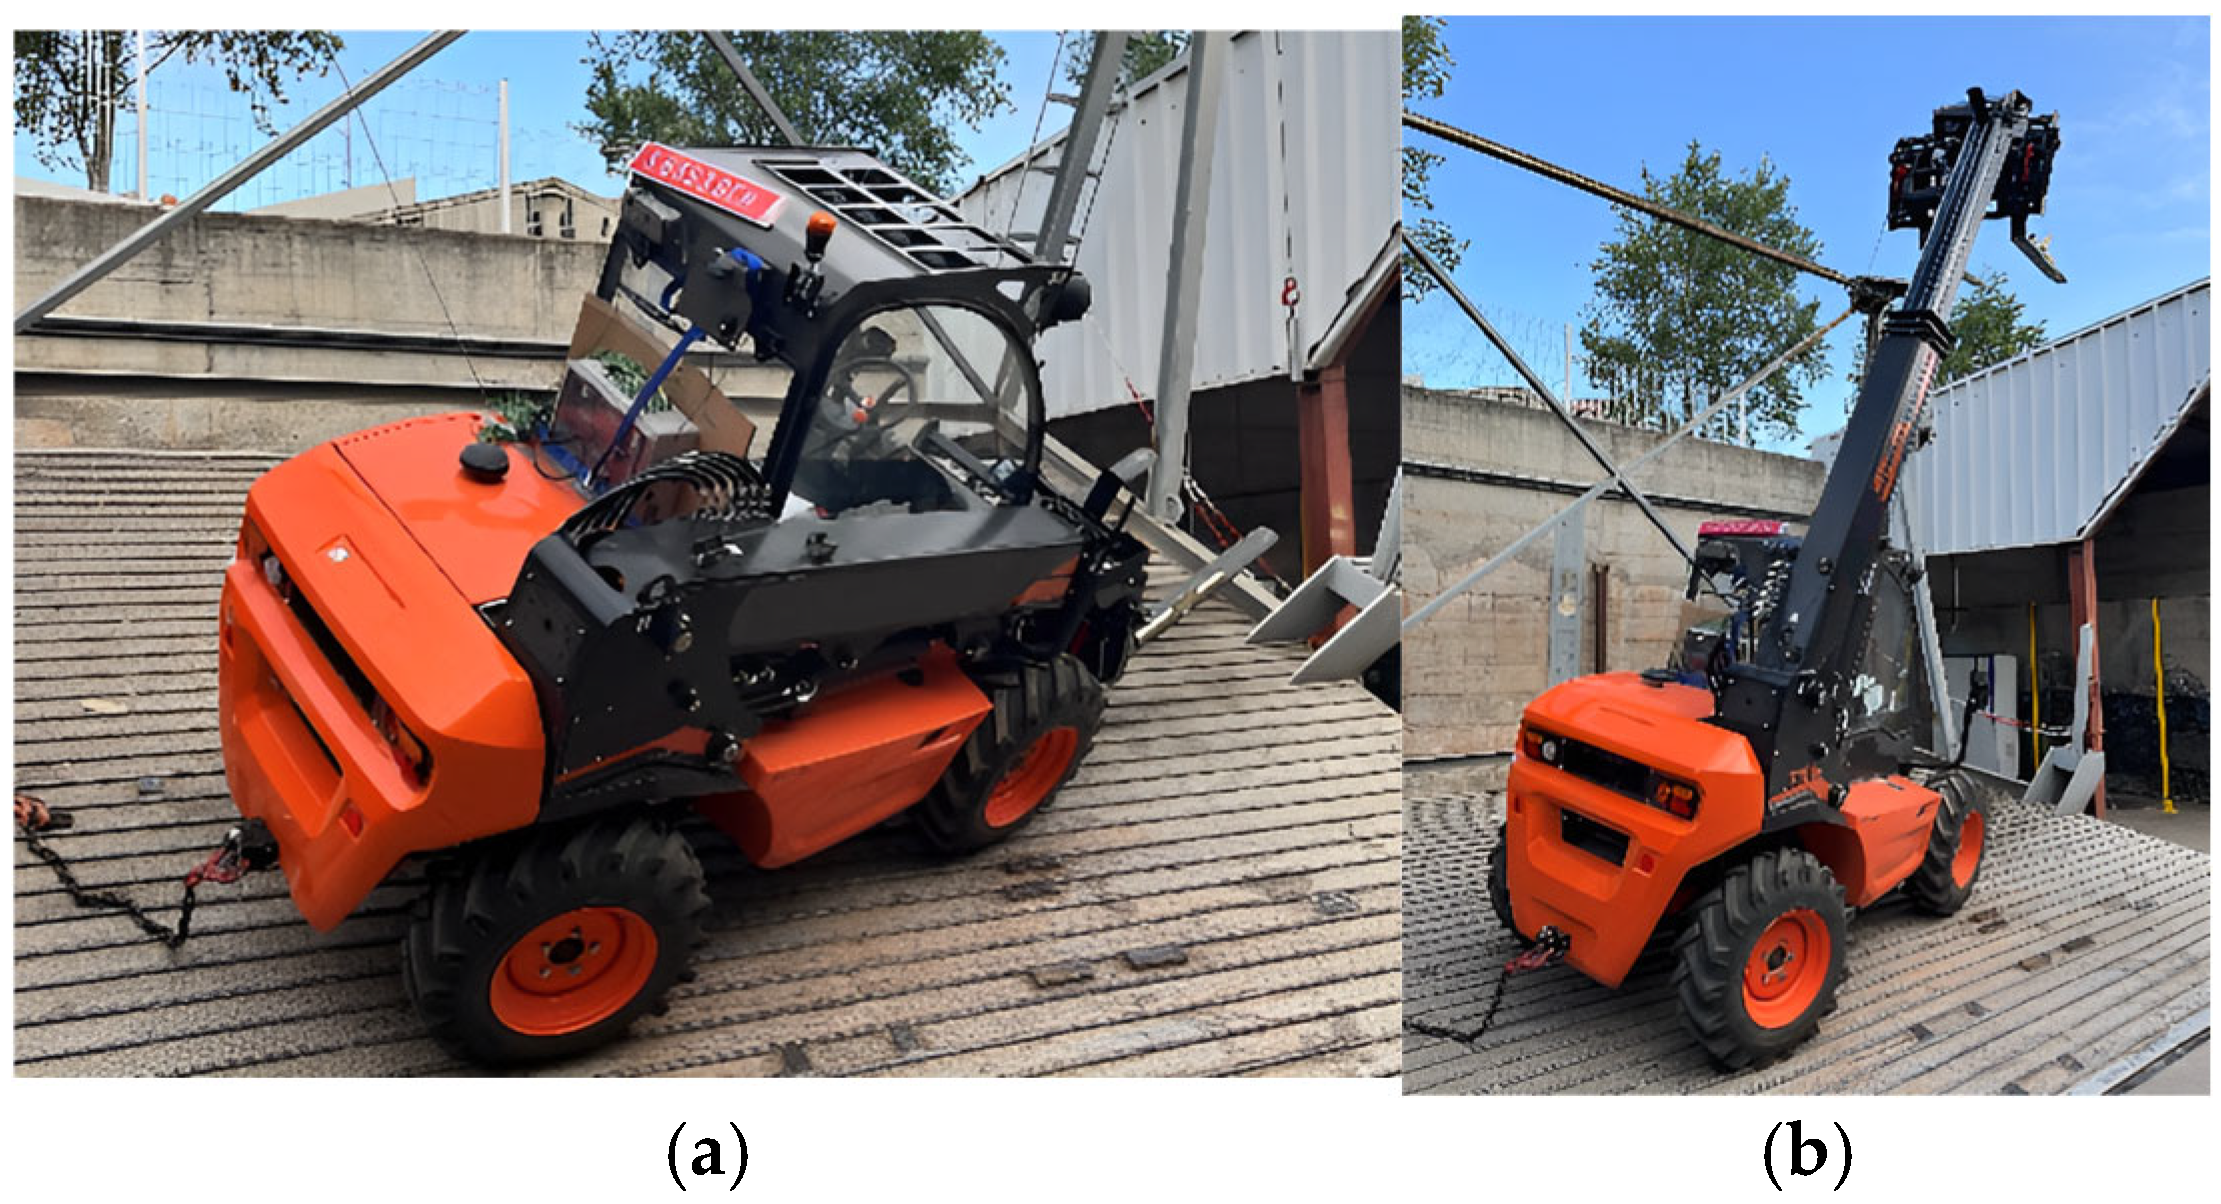
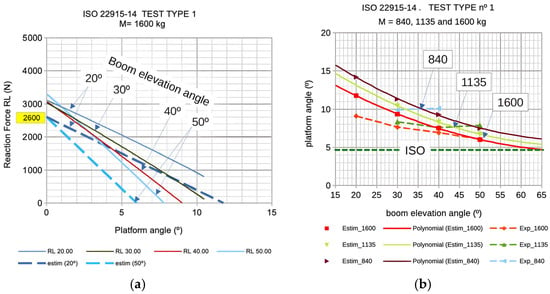
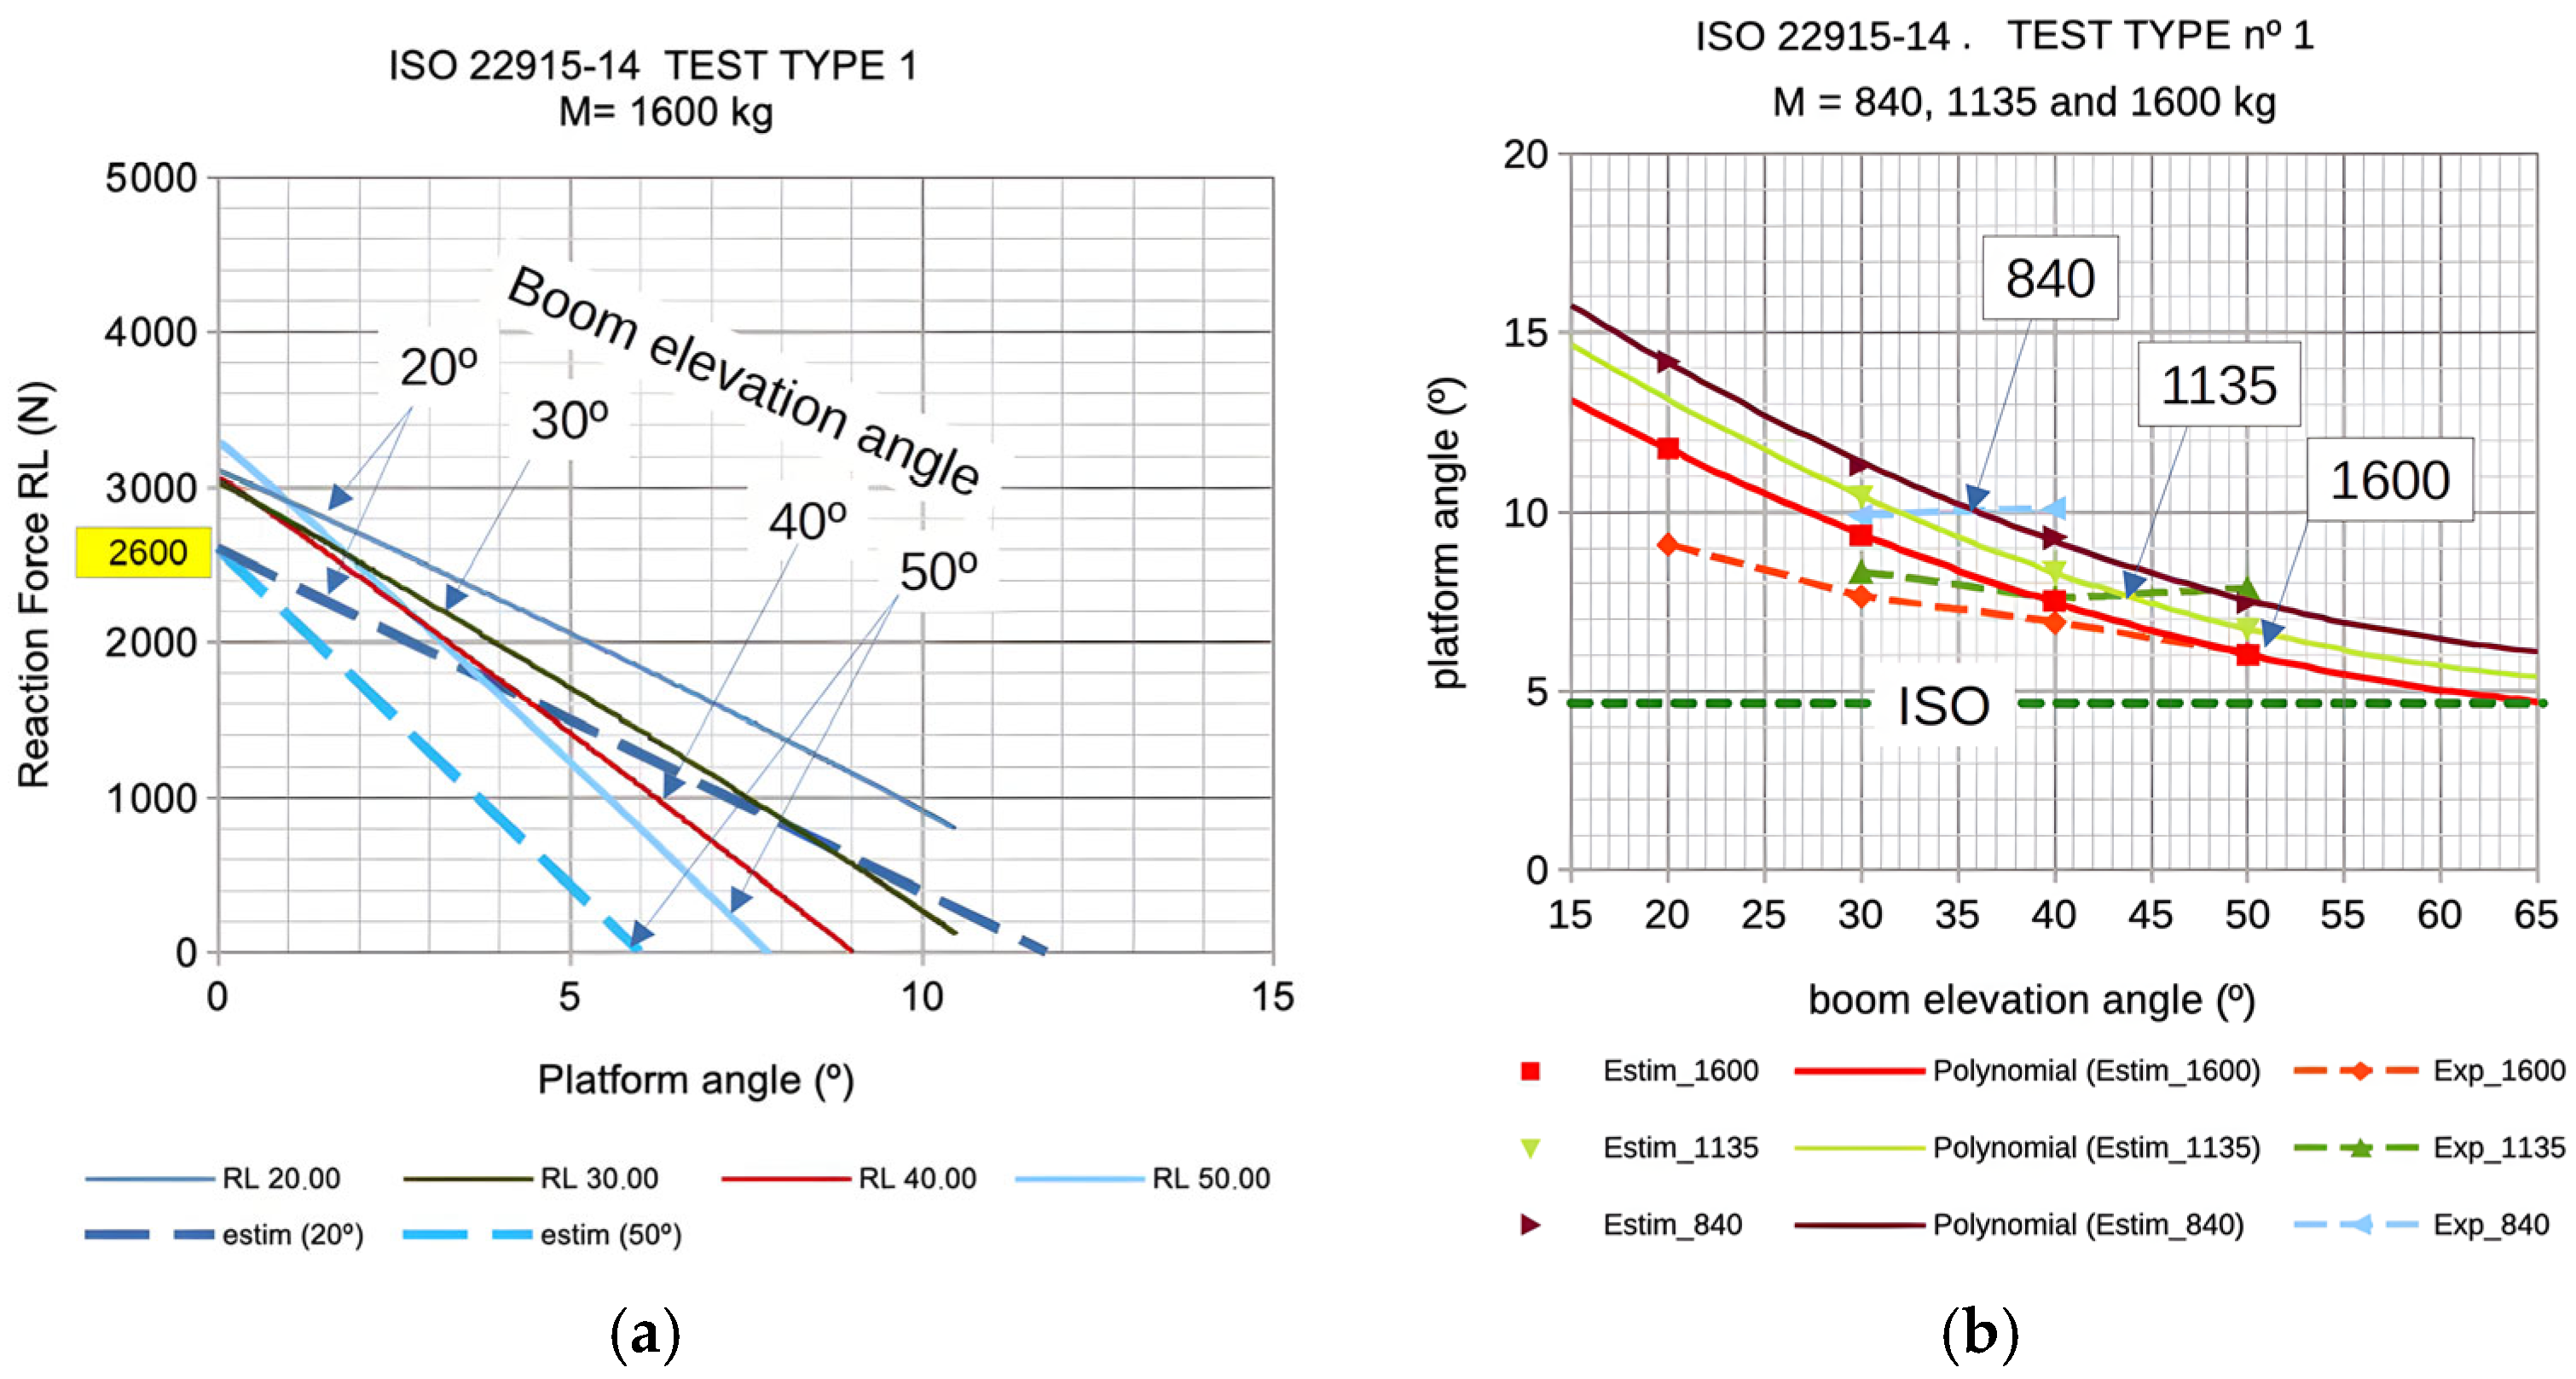
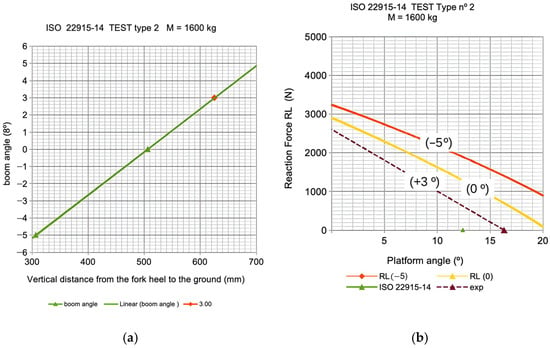
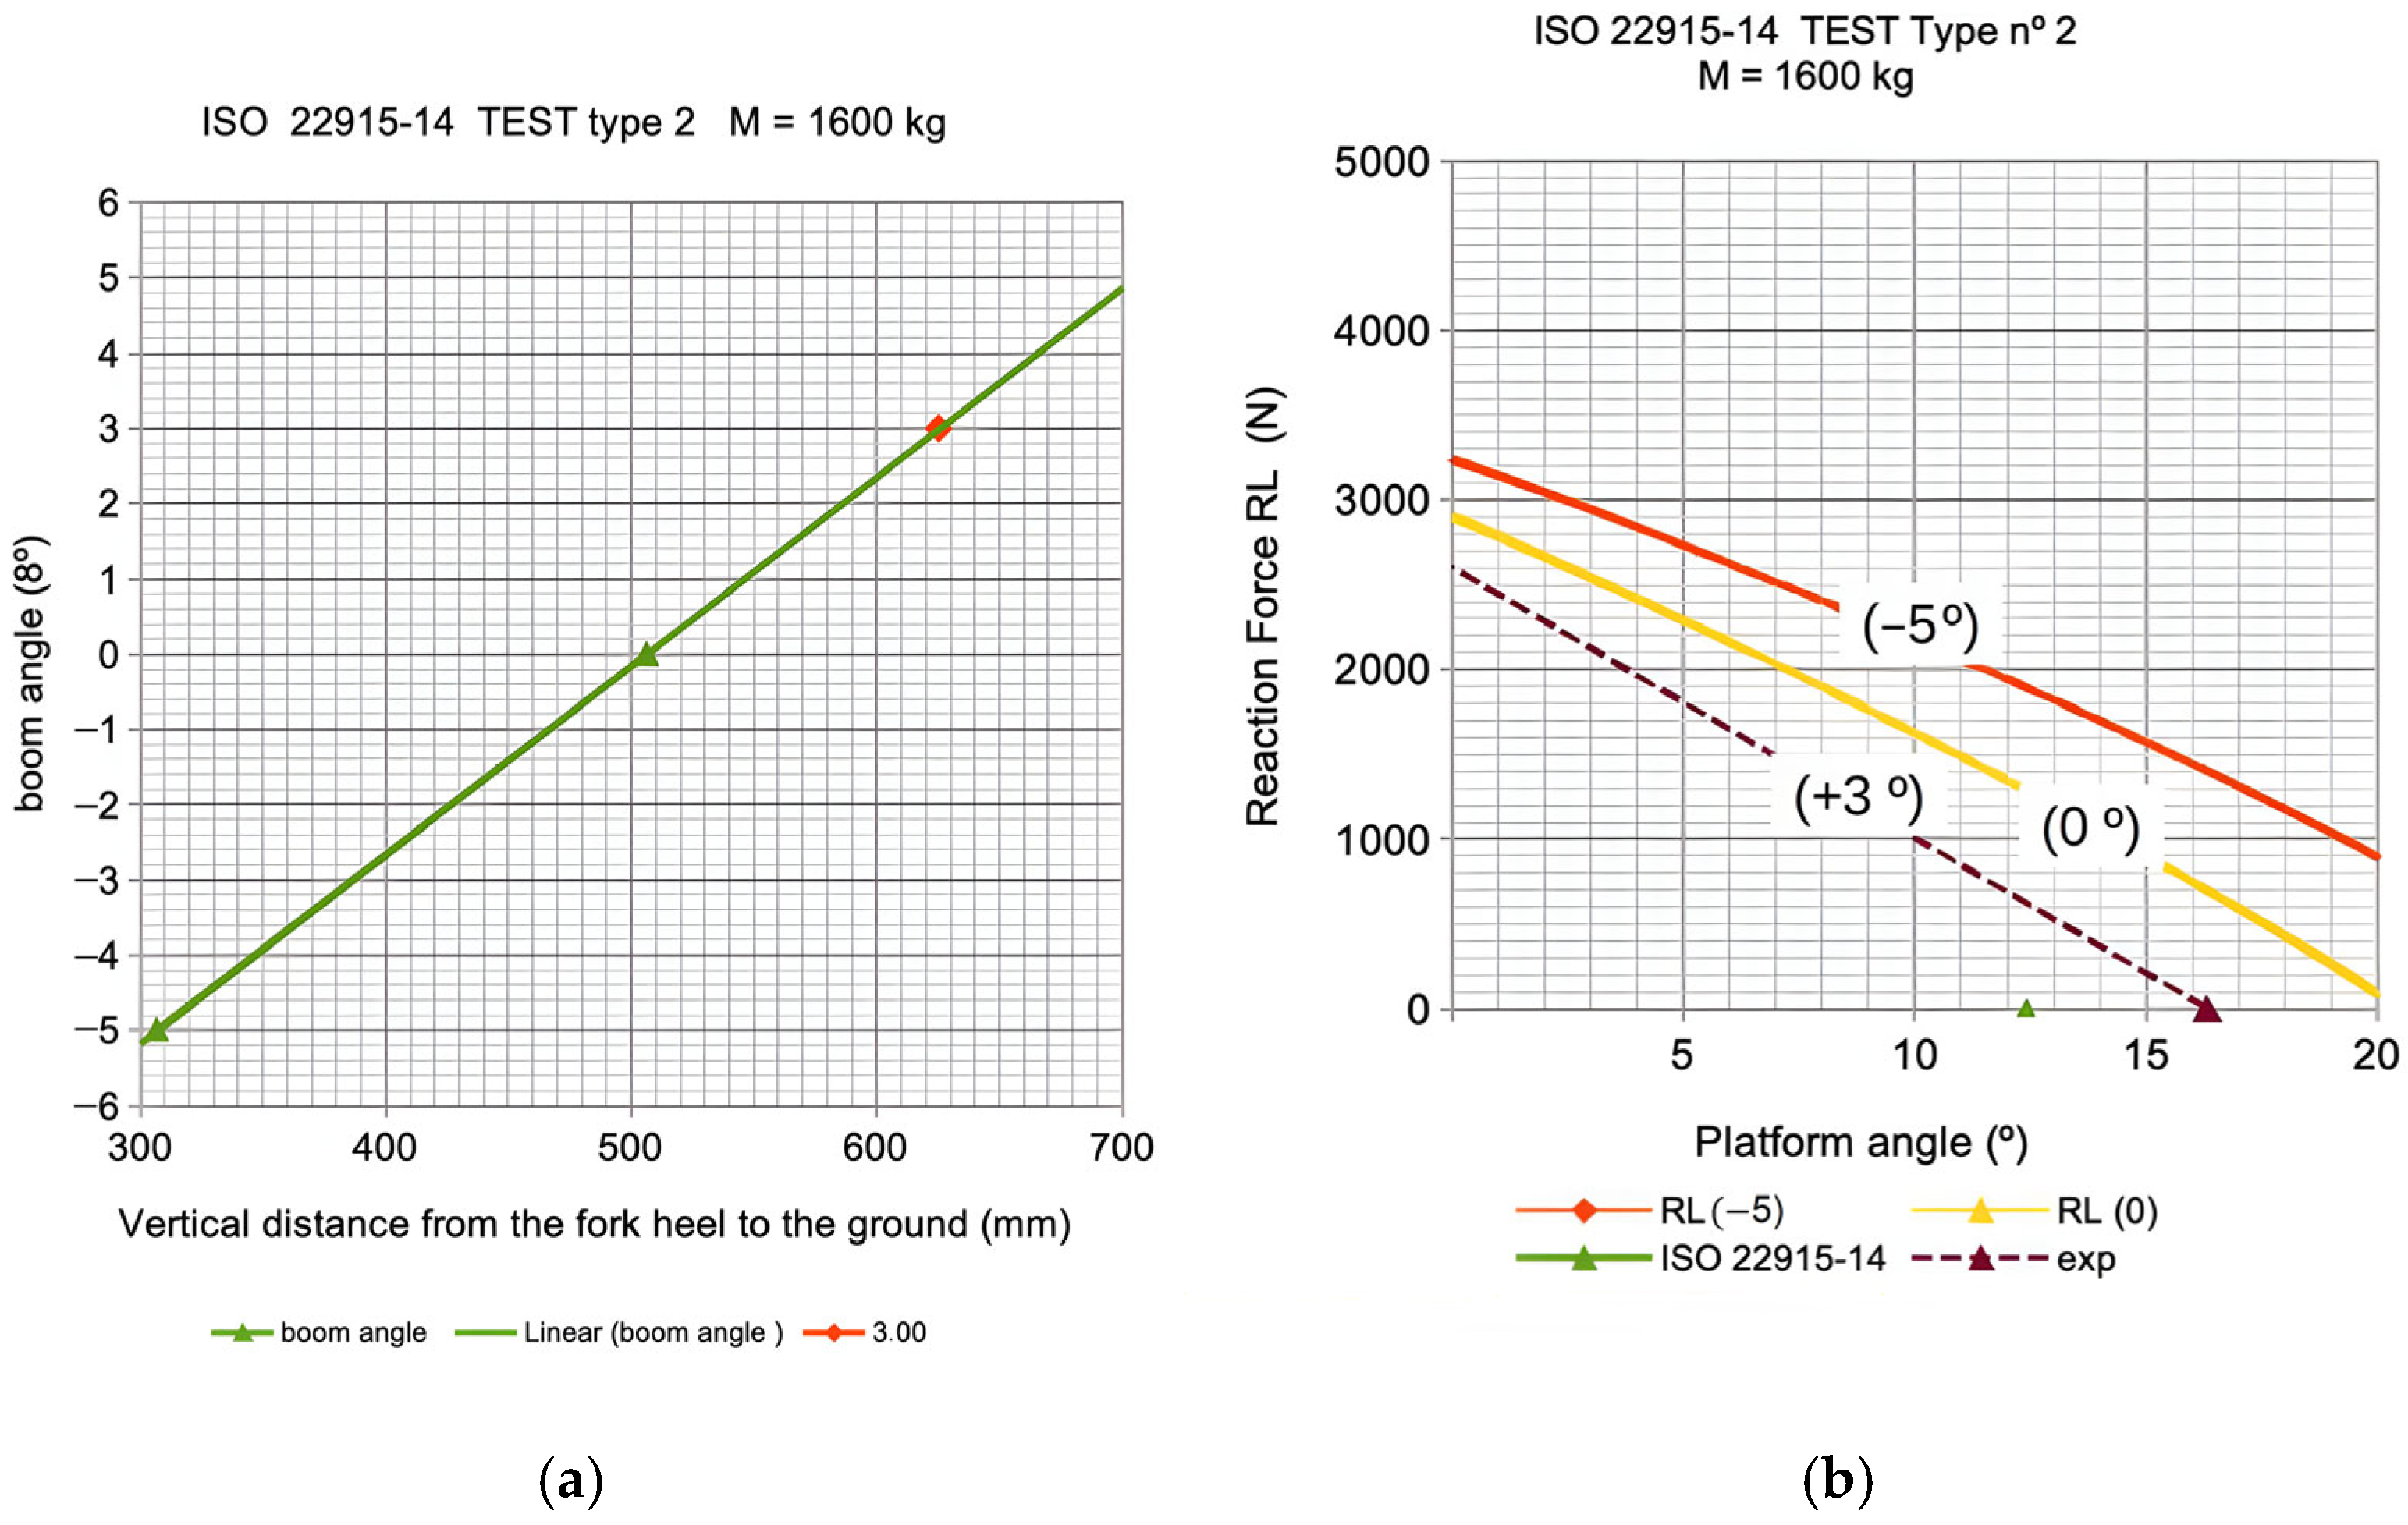
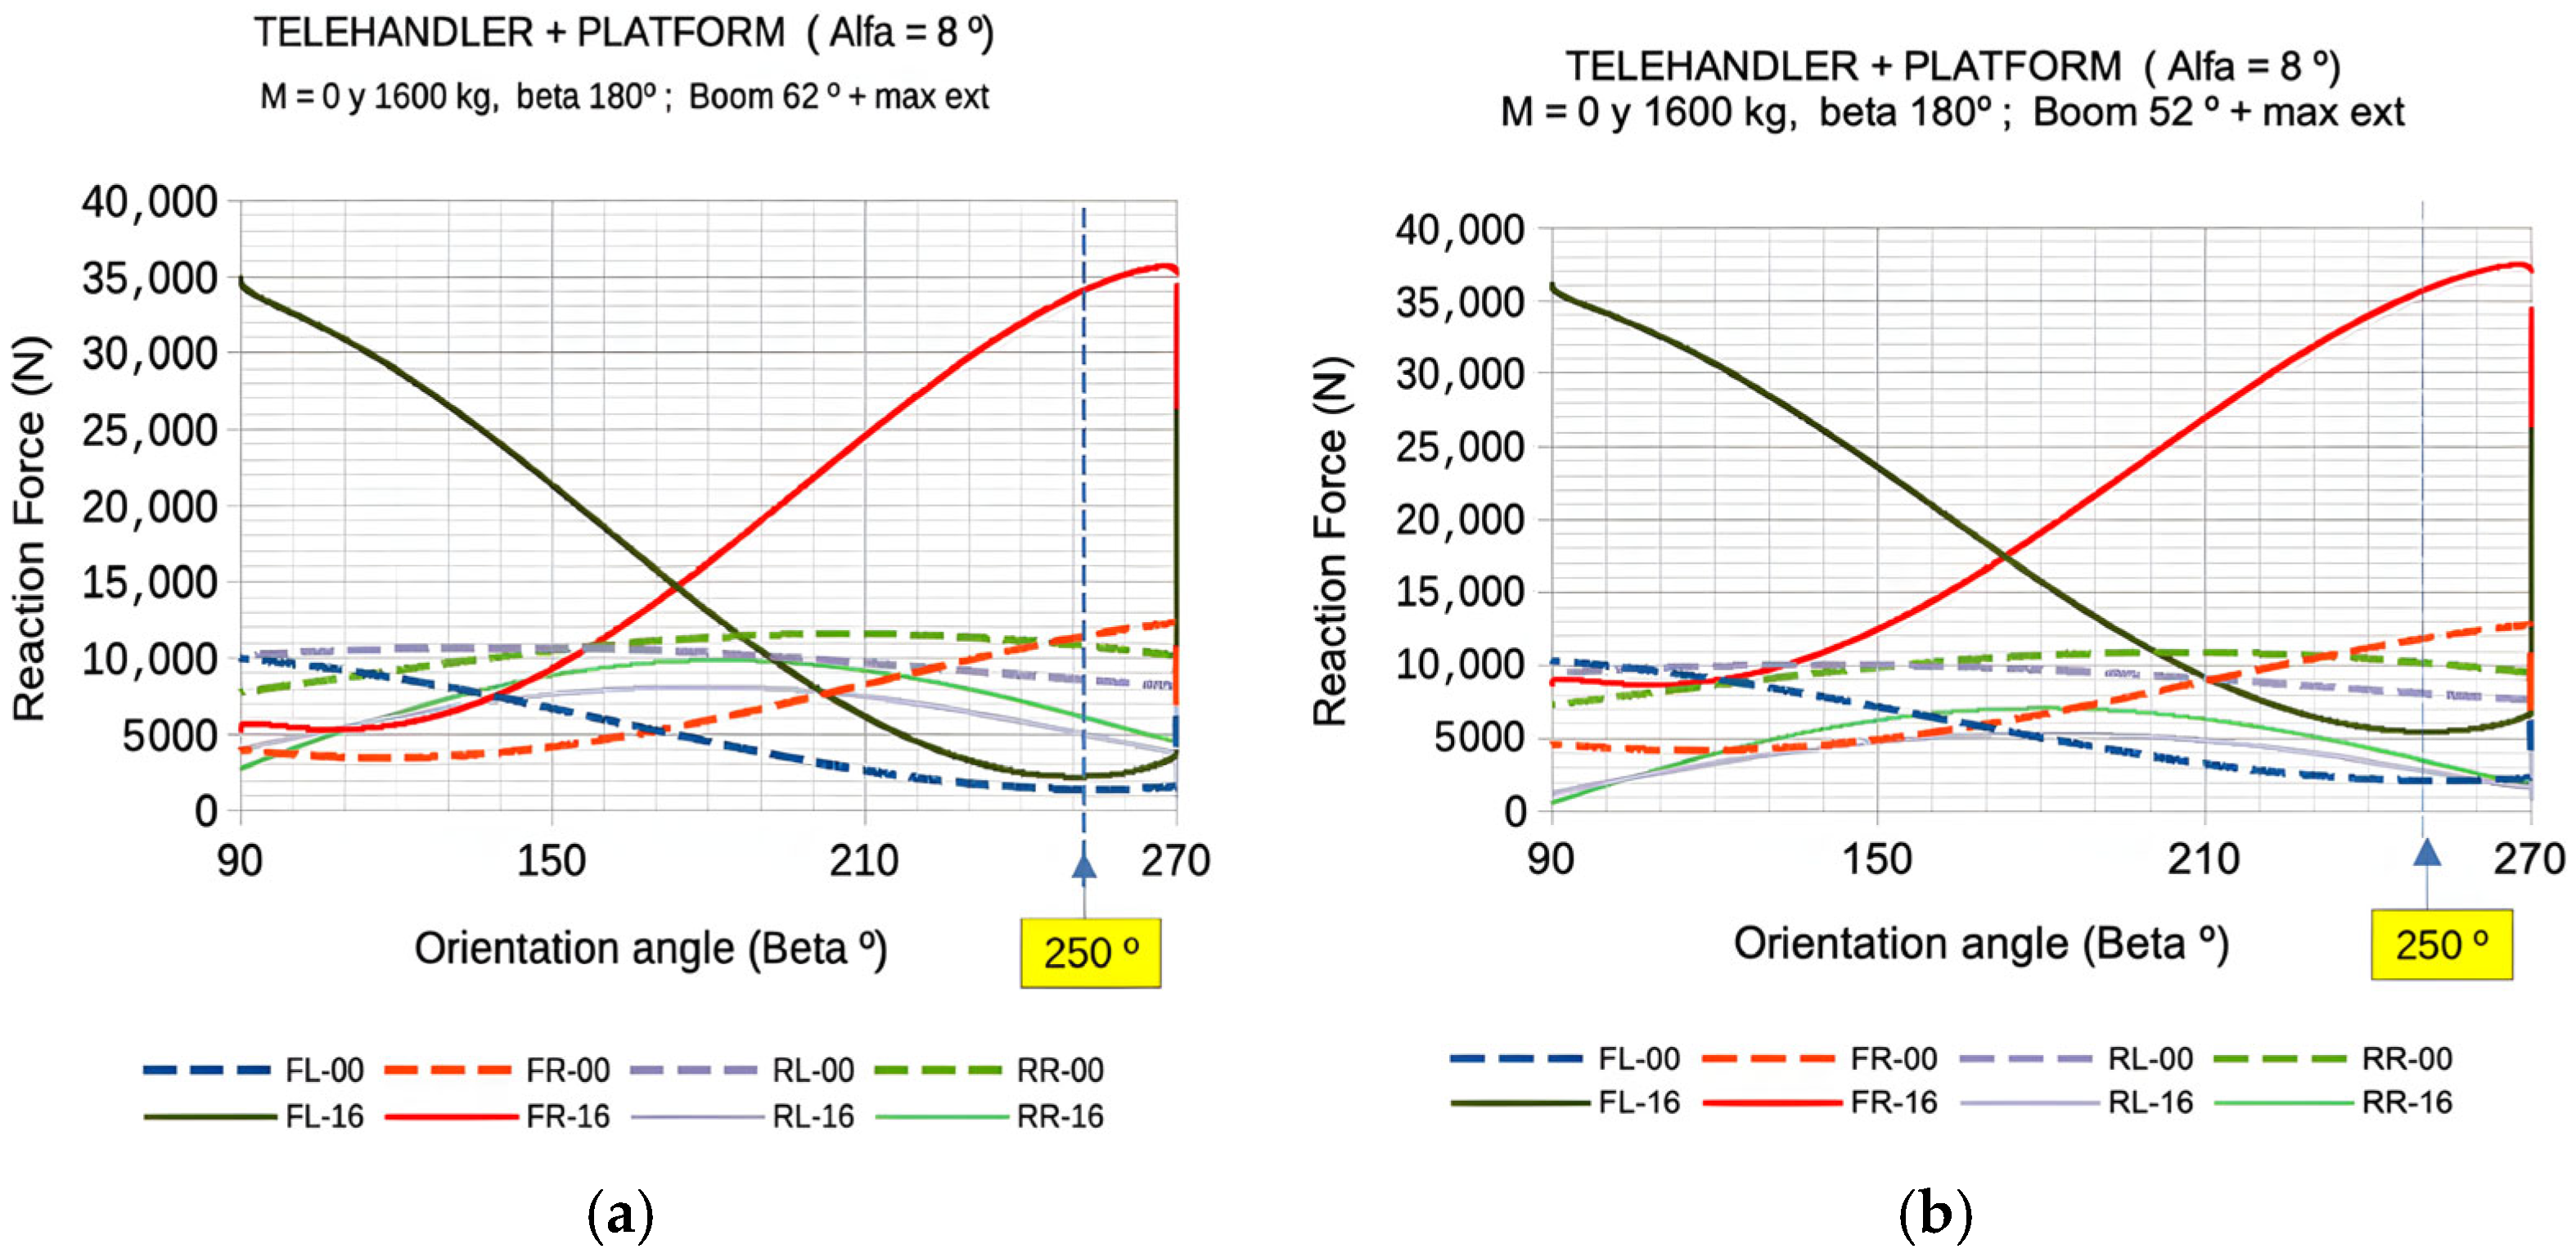
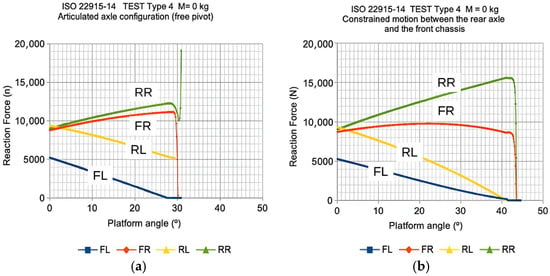
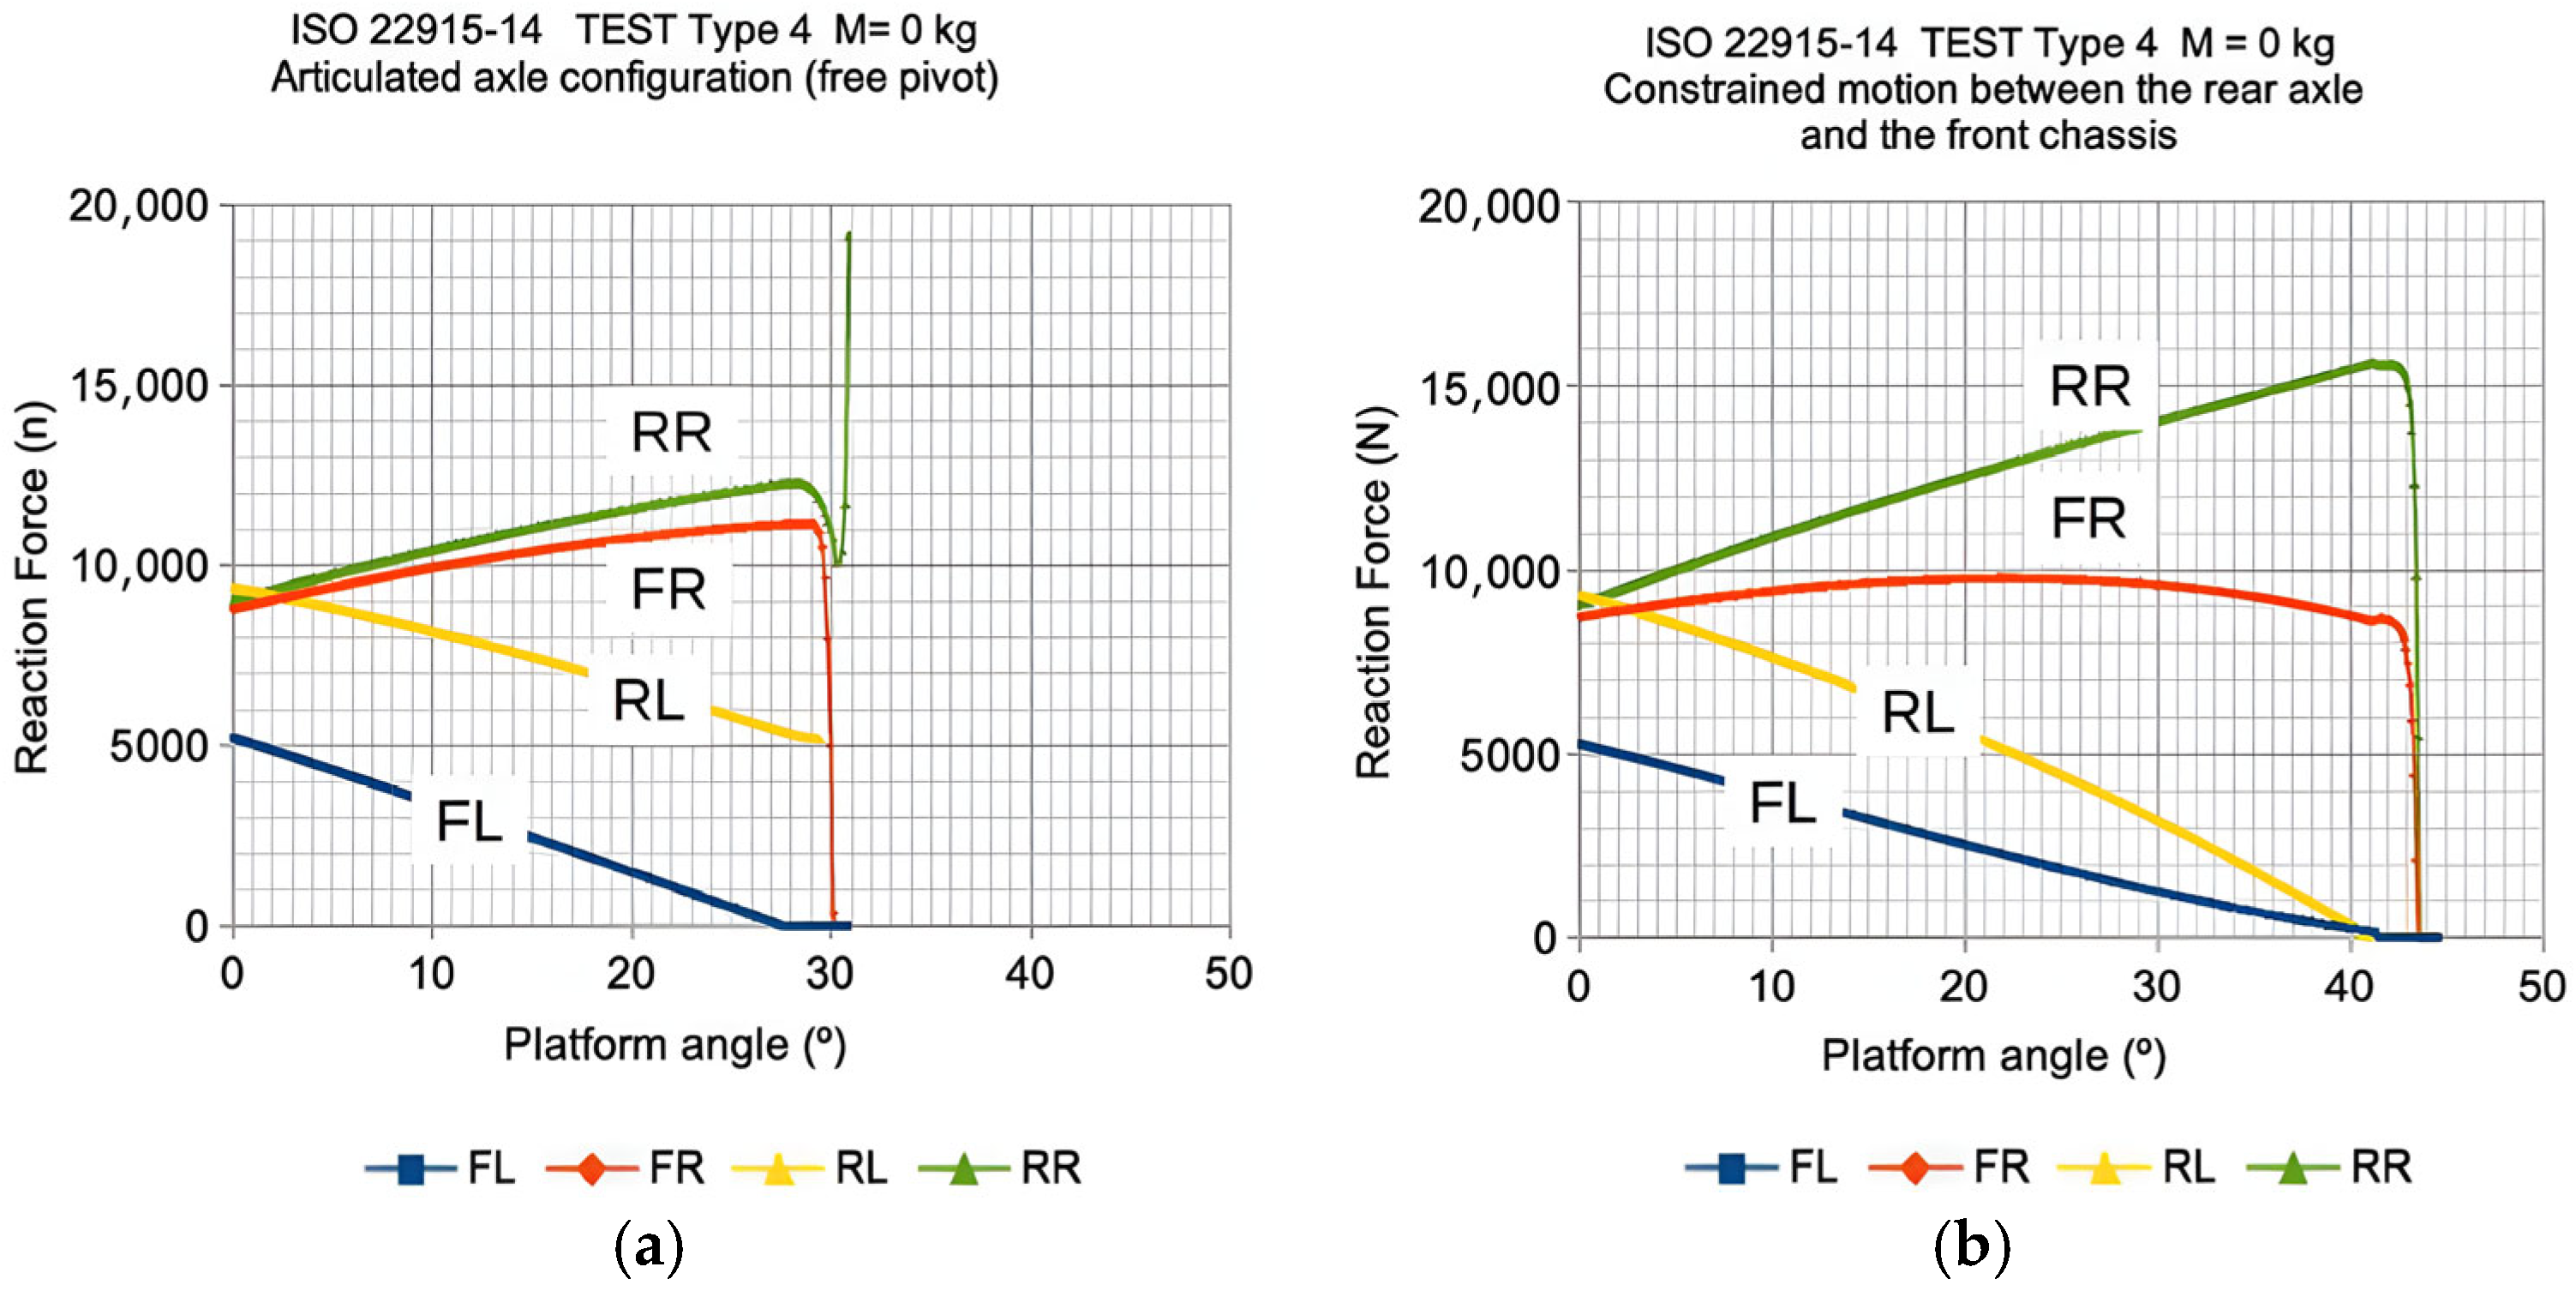
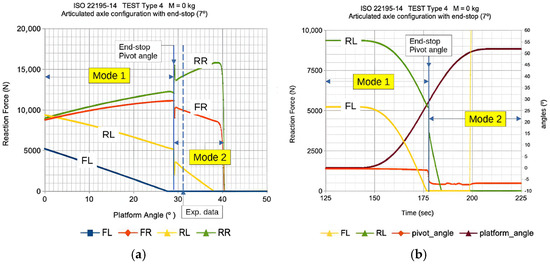
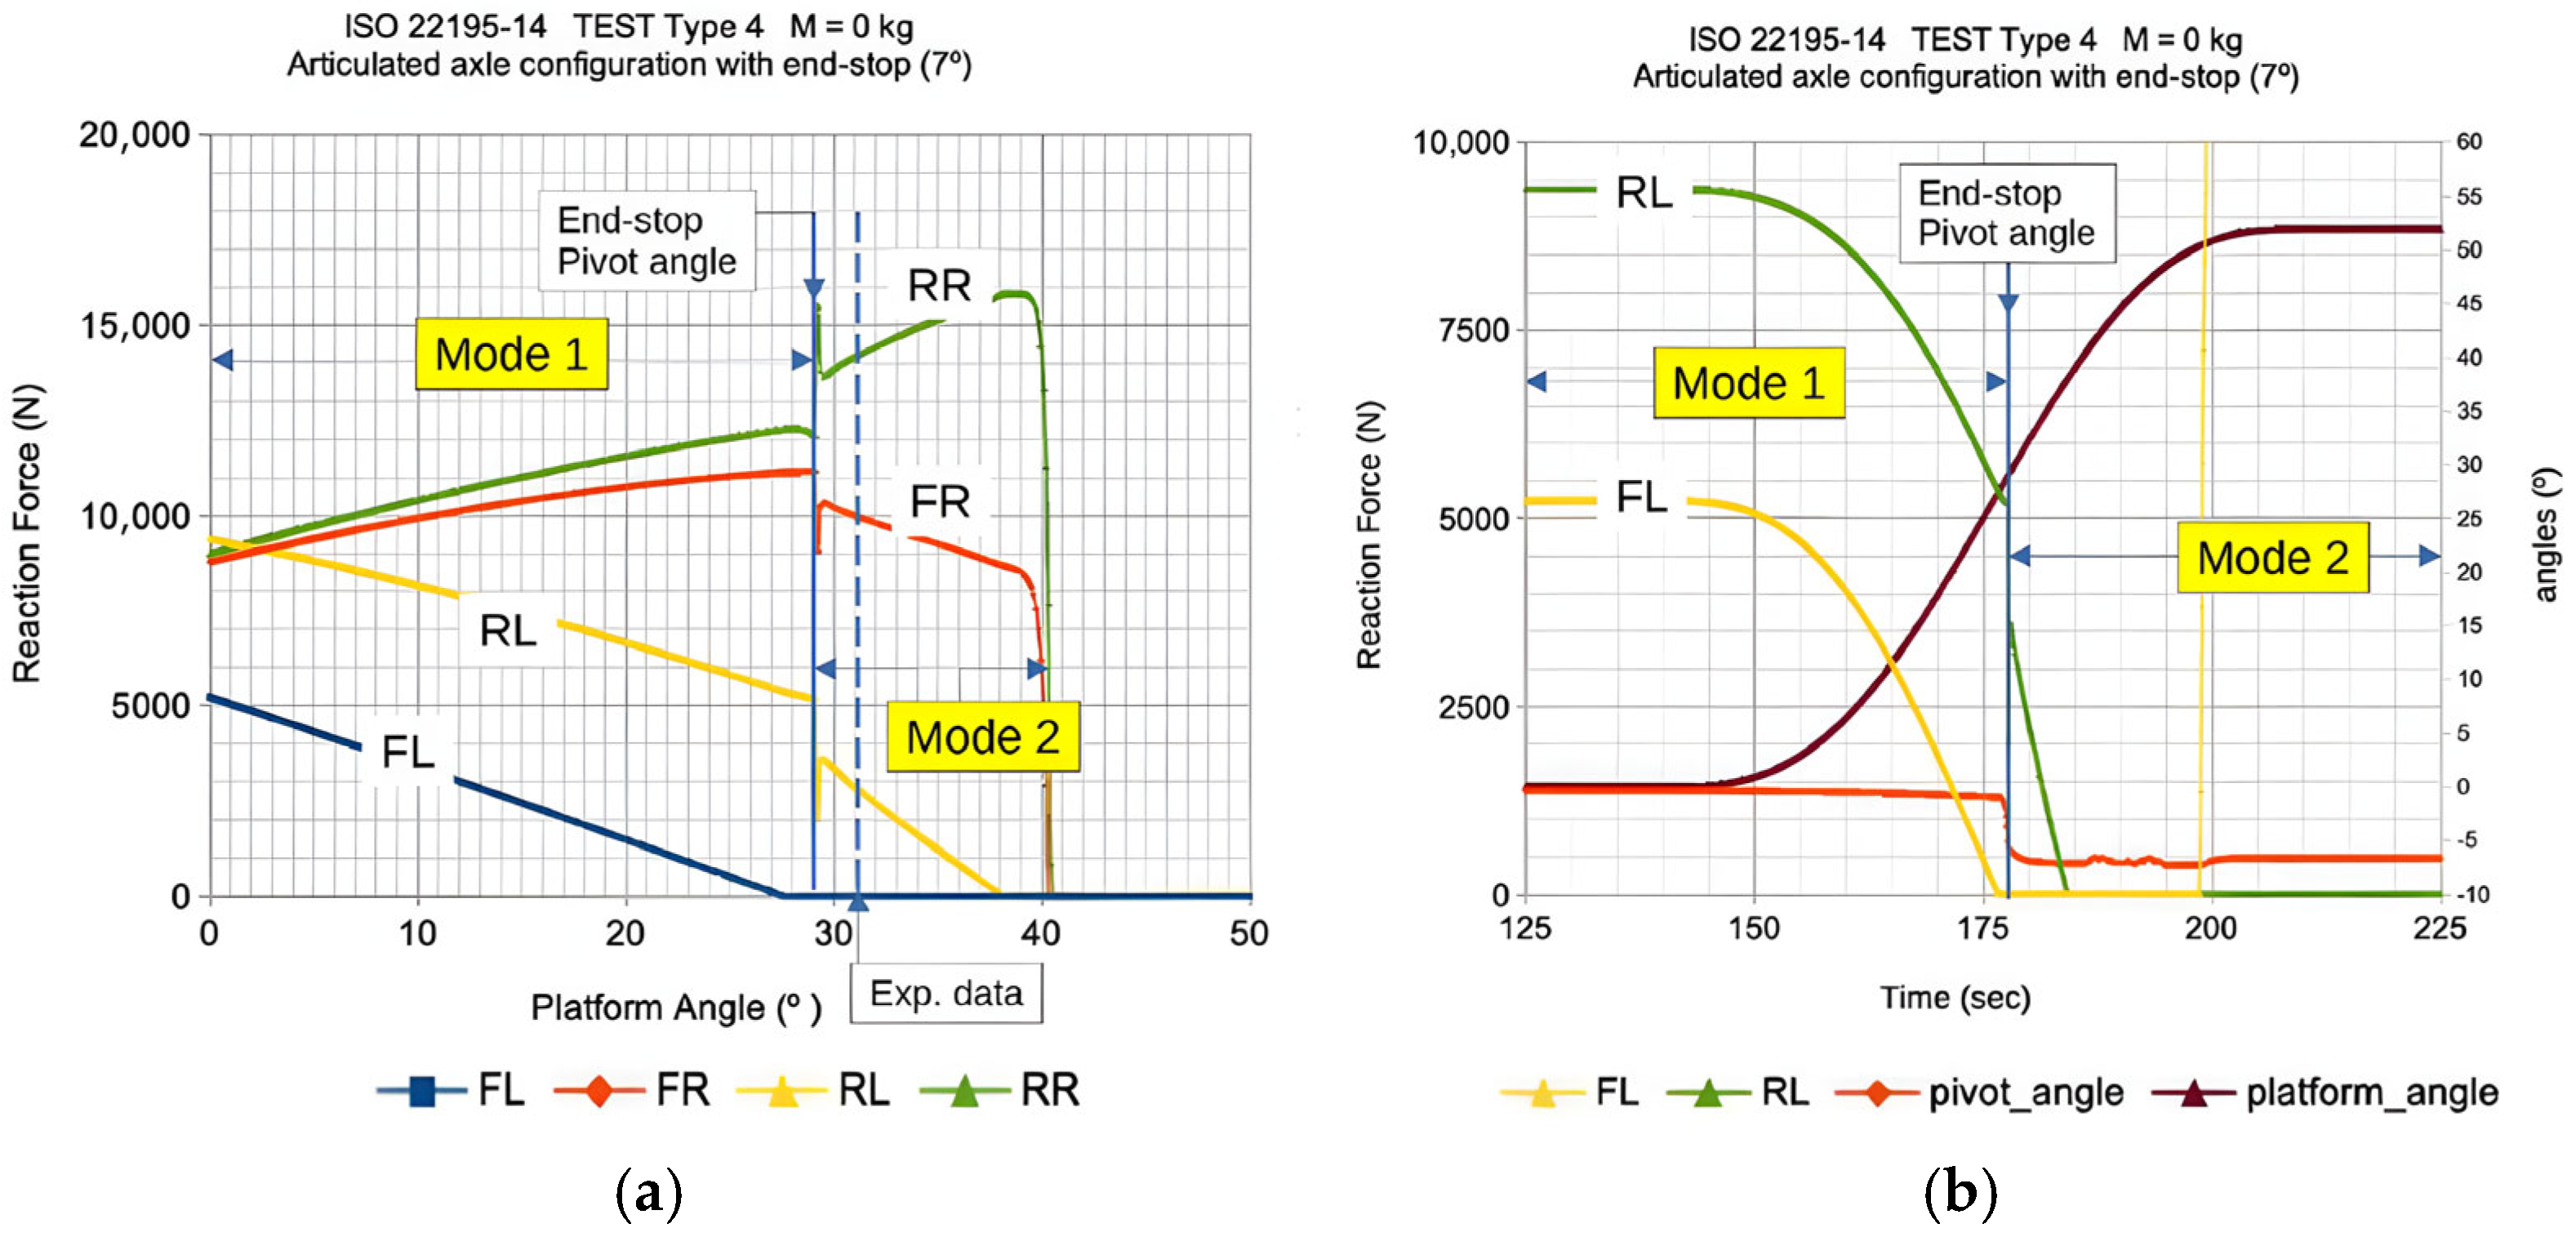

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.