


Abstract
The information symmetry between humans and machines can enhance mutual perception and understanding, leading to more robust cooperation. Intention recognition is a key technology in natural human–machine collaboration (HMC). However, as the complexity of the system increases, the amount of information and the types of tasks become numerous, which leads to continuous dynamic changes in interaction intentions. New sensing technologies such as electroencephalogram (EEG) have provided a continuous and unobtrusive monitoring approach to accurately and effectively identify intentions. But the complexity of physiological responses and the uncertain nature of intention make cross-subject recognition difficult, resulting in poor generalization performance and coarse-grained recognition patterns. To address these limitations, we proposed a framework for modeling tasks in complex systems and applied it to model tasks in an industrial system. Then, we use operators’ EEG data to effectively recognize the fine-grained intention patterns within different typical task scenarios, such as monitoring production and communication tasks. By inputting the improved multi-channel phase synchronization features into a machine learning classifier, cross-subject accuracy rates of 99.42% and 99.91% were achieved. This work furnishes systematic, field-tested cases for task modeling in the industrial field, demonstrates high-performance implicit intention recognition with a single EEG modality, and refines the granularity of implicit intention recognition. It provides theoretical underpinnings and technical support for both human–machine information symmetry and the advancement of HMC hybrid intelligence.
1. Introduction
As a key milestone of the “China Manufacturing 2025” strategy, the past year has seen a series of policies introduced around its core objectives to promote the digital transformation, intelligent upgrading, and high-quality development of manufacturing. For example, the “Steel Industry Steady Growth Work Plan (2025–2026)”, the “14th Five-Year Plan for Intelligent Manufacturing Development”, the “Guiding Opinions on Accelerating the Transformation and Upgrading of Traditional Manufacturing”, and the “Industrial Internet Innovation and Development Action Plan” have elevated artificial intelligence technology from an auxiliary tool to a core engine of new productive forces. The intelligent upgrading of industry and manufacturing is a crucial measure to enhance national core competitiveness, playing a vital role in promoting the development of related industries and economic prosperity, advancing technological progress, and improving people’s living standards [1].
The ultimate goal of industrial intelligence is to achieve full-process automation and even “unmanned” production. However, multiple pieces of evidence—including system complexity, domain-specific differences, dynamic environments, situational diversity, and social-ethical and legal constraints—indicate that fully autonomous intelligent systems remain an unattainable ideal in the foreseeable future [2,3]. In current major scenarios, critical tasks and processes require human intervention to ensure complete and correct behavior under all circumstances, and dynamic human–machine collaboration to maximize system safety and efficiency [4,5]. How to integrate human intelligence into intelligent systems has become a core challenge for next-generation industrial systems, urgently requiring breakthroughs to support real-time human–machine–environment mapping, adaptive interaction, and efficient collaboration.
Intention recognition technology is the key technology of HMC, which can help enhance mutual perception, understanding, and adaptation between the two intelligent entities, and improve the level of information symmetry of the system [6]. Information symmetry refers to the degree of equality in information acquisition, understanding, and feedback abilities. It serves as an indicator of whether both parties maintain complete transparency and information symmetry, thereby achieving “symmetrical communication” at the information level to minimize misunderstandings and enhance collaborative efficiency.
In human–computer interaction (HCI), intention refers to the goals and expectations users wish to achieve when interacting with computer systems [7]. Based on whether intentions are explicitly stated, they can be further categorized into explicit and implicit intentions. Explicit intentions refer to those clearly expressed by users through text or actions, which are determined by integrating textual input, voice commands, machine actuator behaviors, and environmental signals during interactions. Implicit intentions, however, are not explicitly stated by users, making them more elusive and harder to recognize [8]. They exhibit non-obvious characteristics, lack clear triggers, and rely on situational and physiological signals, resulting in high ambiguity that makes direct identification challenging. Consequently, the recognition process involves significant ambiguity and technical difficulties. Unlike explicit intentions that require behavioral cues and thus exhibit certain delays, implicit intentions recognition holds great significance for predicting user behavior, enabling natural HCI, and facilitating efficient collaboration. As system intelligence continues to advance, most human–computer communication relies on interfaces. This interface-based display and interaction format inherently manifests HCI through implicit intentions. Given their concealed nature, difficulty in detection, and ambiguous uncertainty, recognizing implicit intentions presents immense challenges.
Physiological sensing technology provides innovative perspectives and practical solutions for embedding implicit intentions. The dynamic physiological changes during interactions enable the integration of intentions into environmental and system models. Among various physiological measurement techniques, electroencephalography (EEG) serves as a crucial neurophysiological signal reflecting brain cognitive processes. Due to its direct correlation with central nervous system activity and cognitive functions, EEG demonstrates superior sensitivity and accuracy in capturing cognitive states compared to other physiological signals, providing vital human factors for HMC [9]. With advantages including non-invasiveness, portability, simplicity, cost-effectiveness, and high temporal resolution, EEG has become the preferred technology for modeling intentions, paving the way for engineering applications.
Research on EEG-based implicit intention recognition traces back to the five-category cognitive task paradigm proposed by Keirn and Aunion [10]. Scholars have successfully decoded five cognitive task intentions using single-modal EEG through this framework. Building on this research, HCI scholars have extended the experimental paradigm to both human–computer interaction and brain-controlled computer domains. In the study of decoding implicit intentions from physiological signals, motor cognitive intention has received the most attention and the highest decoding effect. For example, Zheng et al. enhanced the classification performance of motor imagery (MI) intention EEG signals through improved feature extraction algorithms [11]. Wang et al. expanded the MI research boundary by combining the experimental paradigm with the task characteristics of human–machine systems, and the multi-category recognition of three kinds of intentions, such as imaging left turn, right turn and shooting, was realized by the aircraft operator via eye movement and EEG signal fusion [7].
Current research on implicit intentions predominantly focuses on cognitive task intentions, MI, target preferences, and behavioral decision-making. Intentions that can be well-recognized are mostly those with significant physiological response differences across different tasks, for example, users imagine left and right, perform various cognitive tasks [12,13]. However, within a specific task, there are also different intention patterns. The cognitive components involved in these subdivided intention patterns are similar to the induced physiological signals, so it is more difficult to identify. Most studies employ multi-modal physiological signal fusion modeling, with single-modal recognition yielding limited results, which restricts the implementation of intention experiments and the application of recognition technologies.
In the field of fine-grained intention pattern recognition, Park et al. developed an intention recognition system based on eye movement and EEG, addressing two types of implicit intentions during user browsing: purposeful visual search and aimless general browsing [14]. However, single-modal EEG yielded limited results. Slanzi et al. investigated click decision-making intention patterns when users browse websites naturally based on eye movement and EEG [12]. They found that eye movement features demonstrated good discriminative power, though the final recognition accuracy remained low. Kang et al. employed a phase-synchronous multi-channel EEG signal processing method to extract intention features, achieving 63.6% accuracy in cross-subject model recognition by collecting EEG signals induced during visual browsing under various target scenarios [15]. Current research on fine-grained intentions demonstrates limited diversity in pattern types, with most studies focusing on synchronizing multi-channel and multi-domain EEG features. While individualized modeling approaches can achieve high recognition accuracy, their generalization performance across subjects remains suboptimal.
Furthermore, intention recognition is domain-specific and task-oriented. Current research predominantly focuses on simple systems or everyday applications, with limited attention paid to security-centric complex systems in industrial and applied fields. This gap results in existing quantitative computational dimensions of operators’ physiological, psychological, behavioral, and intent characteristics being unsuitable for modeling complex systems. There remains insufficient analysis of domain-specific brainwave patterns for intent detection and inadequate exploration of intent modeling techniques. To bridge this gap, it is essential to integrate task-specific features, expand current research paradigms, and deepen the scope and breadth of HCI studies.
Against this backdrop, this study addresses the requirements of human-centered Industry 5.0 and safety-focused industrial intelligent systems. By leveraging single-modal EEG signals, it aims to achieve fine-grained recognition of implicit intention patterns in critical tasks within industrial HMC systems. The research explores natural human integration into intelligent systems, enhances human–machine hybrid intelligence, and promotes quantified human computation and bidirectional robust human–machine understanding. This work furnishes systematic, field-tested cases for task modeling in the industrial field, demonstrates high-performance implicit intention recognition with a single EEG modality, and refines the granularity of implicit intention recognition. It provides theoretical underpinnings and technical support for both human–machine information symmetry and the advancement of HMC hybrid intelligence.
2. Related Research
2.1. EEG Induction and Acquisition
The evolution of intention-based experimental paradigms is intrinsically linked to the iterative upgrading of systems. As complexity increases, these experiments have progressed from static material demonstrations and imagination exercises to prototype systems with interactive support. The experimental environments—featuring materials, task designs, and interaction mechanisms—now increasingly mirror real-world system applications. Figure 1 illustrates the developmental trajectory of intention-based experiment paradigms.
Figure 1.
Evolution of the intention experiment paradigms.
In early experiments, given the simplicity of the system’s characteristics, intention-evoked EEG stimuli were created through basic interaction scenarios. Participants primarily relied on cognitive imagination or performed simple tasks to complete the experiments.
Researchers like [15,16] focused on user intentions in visual browsing scenarios. They used common real-life scene images as stimulus materials, sequentially presenting five scene images per intention category. Participants completed two types of EEG signal collection—target search and random browsing—following experimental instructions, with the entire process requiring no physical operation. The intention-evoked materials and experimental procedures are illustrated in Figure 2a. The mental tasks intention experiment paradigm designs corresponding intention-inducing materials based on the characteristics of each mental task [17]. Figure 2b shows the intention-inducing materials for the geometric body spatial rotation. Participants sit in front of the display, visually process static materials, and mentally perform the cognitive task as required by the experimental task. The motor cognitive intention paradigm primarily employs motor imagery experiments, where participants visualize specific body movements to activate corresponding brain regions. The standard procedure involves establishing a baseline in a relaxed state, triggering motor imagery through auditory cues, and then performing the imagery task.
Figure 2.
Early stage intention triggering way: (a) informational intention and navigational intention; (b) geometric control rotation intention triggering materials for Keirn’s mental task classification experiment.
As HCI systems handle increasingly complex information and tasks, display methods and interaction modes have become more sophisticated. EEG experiments are now being conducted in real-world scenarios. By simulating system interfaces and interaction methods, experimental stimuli and tasks are presented through prototype interfaces, interactive prototype systems, or even real-world systems, while providing interaction support (such as mouse movement, clicks, and joystick tracking) to capture participants’ task EEG signals. Prototype systems maintain close resemblance to real HCI environments while avoiding excessive system details that could compromise the transferability and generalizability of recognition models.
Wang et al. utilized driving simulation software to capture drivers’ braking intentions in real-world scenarios [18]. See Figure 3a. By implementing varied external conditions (including different road conditions and speed levels), they induced three types of driving intentions: normal driving, adaptive braking, and emergency braking. The experiment captured EEG activity patterns under these conditions and classified braking intentions using EEG signals. Wang et al. developed an experimental stimulus interface prototype based on typical pilot-aircraft interaction scenarios. The prototype incorporated two types of intentions—motor imagery and shooting intent—along with three intention patterns: imagining a left turn, imagining a right turn, and shooting intent [7]. The experimental scenario is illustrated in Figure 3b.
Figure 3.
Induce user’s task-related EEG signals through carrying out interactive tasks: (a) Braking intention during driving; (b) simulated military aircraft intent scenario.
Complex systems often carry out multiple tasks simultaneously. The multi-tasking paradigm such as the Multi-attribute Task Battery (MATB) [19] enables precise control over module difficulty levels with multiple attributes, which has been widely adopted and evolved into various variants due to its controllable nature. See Figure 4a. For instance, in a NASA project, Liao designed four concurrent tasks: tracking, selection reaction, arithmetic calculation, and simulated radar observation [20]. The experimental program interface featured two tiled displays: the right screen presented compensation tracking and selection reaction tasks, while the left screen displayed simulated radar imagery and arithmetic operations, allowing all four tasks to be executed simultaneously. Liang et al. developed a prototype system for military aircraft based on typical operational task patterns and interface design principles [21]. The prototype features four functional zones: radar, table, icon, and control areas, along with five operational scenarios covering rest, visual search, table lookup, communication, and control. This system successfully identified pilot intentions, as demonstrated in Figure 4b.
Figure 4.
EEG induced forms in the multi-task environment of complex systems: (a) MATBII; (b) pilot intention experiment simulating military aircraft environment.
Some intention experiments are conducted in real human–machine system environments, identifying intentions by collecting task-state physiological signals from subjects during natural human–machine interactions. These experiments focus on natural human-system interactions but face challenges such as data annotation difficulties and poor signal-to-noise ratios in physiological signals induced by real-world environments. Typically, physiological intention signals are supplemented with other physiological, behavioral, or subjective records to label intention types. However, due to implementation difficulties, low data quality, and processing challenges, such experiments are rarely applied.
Slanzi et al. documented EEG and eye movement signals from users browsing five real-world websites in natural browsing scenarios [22]. They innovatively labeled intent data using eye-tracking technology to capture physiological signals of gaze behavior. Whether a mouse click occurred after a gaze event was used as an intent classification label, thereby modeling click intent. This combination of eye-tracking and mouse click behavior served as the annotation method for intent types.
2.2. Data Analysis and Modeling
In EEG recording, multiple electrodes are distributed in different locations of the scalp, and the EEG signals recorded by each electrode contain information about neural activity in different regions of the brain. The generation of intention leads to specific changes in the EEG signals of different regions of the brain.
Traditional EEG analysis methods focus on detecting differences in brain regions and channels, identifying distinct features through comparative analysis. For instance, Slanzi et al. used pupil diameter data in eye movement analysis as features and extracted 789 EEG feature values across time-domain, frequency-domain, and complexity metrics from 5 frequency bands and 14 channels [22]. Using a logistic regression model, they achieved 71.09% accuracy in intent recognition. Wang et al. integrated time-domain EEG features with frequency-domain power spectral density (PSD) characteristics to classify three driving intentions: emergency braking, soft braking, and normal driving [18]. The study revealed that braking intentions significantly enhance PSD in the 40–60 Hz range, with emergency braking showing more pronounced PSD increases and shorter durations. By screening EEG features with significant differences and applying a Support Vector Machine (SVM) classifier, the researchers achieved over 74% accuracy in identifying braking intentions.
However, intention involves complex information processing and multiple cognitive stages, with information exchange occurring between different brain regions and channels. Traditional EEG feature extraction methods use significantly different brain regions or channels as modeling inputs, neglecting the underlying mechanisms of intent generation, which results in low recognition accuracy. EEG spatial domain features focus on synchronicity between brain regions and multi-channel interactions [23]. Phase information in EEG is highly effective for pattern recognition [24]. Phase locking values (PLVs) reflect the degree of phase synchronization between channels, which has been proven to better represent implicit intentions and is widely applied in motor intention and attention intention recognition. For instance, Park et al. compared the magnitude and variation in PLV values under two visual browsing intentions, finding that the accuracy of classification improved by approximately 5% when integrating EEG and eye movement signals compared to single EEG signal modeling [14]. Kang et al. employed a multi-channel EEG phase synchronization method to extract intention features [15]. The experiment collected EEG signals induced by subjects during two scenarios: target-driven visual search and target-free visual browsing. They extracted PLV values across four frequency bands (theta, alpha, beta-1, and beta-2), identified electrode pairs with maximum phase locking values, and constructed intention features using these PLV values. The features were input into three classifiers: SVM, GMM, and NB. The study revealed that SVM achieved the highest classification accuracy with an average rate of 63.6%, demonstrating that brainwave phase synchronization was more pronounced during target-driven visual search than during target-free visual browsing.
This method makes full use of the synchronization of multi-channel signals and has been proven to be effective in the recognition of implicit intention, especially in the conversion of different types of implicit intention. However, current research shows that the accuracy of such algorithms remains relatively low. While individualized models achieve good recognition rates, cross-subject intent recognition rates only reach around 60%. Therefore, how to leverage the advantages of spatial domain features in individual modeling to improve cross-subject algorithms and achieve higher recognition accuracy remains a key challenge in implicit intent research that requires urgent breakthroughs.
2.3. Task Modeling Method
Traditional task modeling relies on subjective requirements and functional descriptions, neglecting quantitative task calculations and human physiological responses. This overdependence on researchers’ prior knowledge results in poor reproducibility and reliability in the extraction process. Consequently, the constructed task models exhibit coarse granularity, only providing a macroscopic view of the overall framework. Such limitations significantly restrict their value in HCI research.
Task analysis based on conceptual models helps clarify system task structures, hierarchical relationships, dynamic execution processes, and predict task outcomes. Current approaches for structurally describing task hierarchies primarily include hierarchical task analysis (HTA), task knowledge structure models (TKS), and predictive error-avoidance models like the GOMS model [25] and HAMSTERS methodology. While these methods define complete task structures and hierarchies, their static nature overlooks external changes and dynamic human–machine–environment interactions. Methods focusing on task execution dynamics better capture human-system interactions. For instance, the CTT model integrates model-based user interface design with formal HCI methods, providing symbols to express subtask execution sequences, transient relationships, and interdependencies [26]. The Rule-Enhanced Task Model extends CTT by embedding business logic through rule-based languages, offering more precise task execution descriptions [27]. The DynaMo-AID model incorporates dynamic device awareness into task analysis frameworks [28]. The Executable Task Model proposed by Klug and Kangasharju [29] adds input/output ports to each task. Although the above model can describe the dynamic interaction process between human and machine, it lacks consideration of the changes in the external environment and the research on the relationship between human and machine.
The PCTBTA (Perceptual Control Theory-based Task Analysis) model, grounded in perceptual control theory, synthesizes the strengths of both aforementioned models by unifying task hierarchy and task execution frameworks while emphasizing dynamic processes. This methodology incorporates all external factors influencing user goal achievement—including environmental, technological, or social relationships—into its analytical model, enabling comprehensive descriptions of user tasks in dynamic environments. By prioritizing perceptual dynamics and integrating external information into task analysis, the model expands its descriptive scope beyond static system-user interactions to encompass dynamic task execution processes. However, the model’s design lacks foundational support in the task objective formulation stage, as both environmental and task specifications rely on subjective expert knowledge and require manual proposal. This top-down approach neglects core elements of HCI systems, particularly the critical focus on operators’ behavioral and physiological data.
In view of the problems in the above task modeling, the complex system needs to combine multiple dimensions, such as the system hierarchy and structure, task execution process and operator physiology.
3. Task Analysis and Modeling
3.1. Method
3.1.1. Dimension, Structure and Elements
Building upon the PCTBTA modeling process, this section outlines a three-tiered framework comprising task extraction, task analysis, and task modeling. It specifies the hierarchical structure, implementation procedures, dynamic response analysis, and multi-source heterogeneous data sources with corresponding analytical methods for each phase, as illustrated in Figure 5.
Figure 5.
Task modeling method.
Task extraction is based on the analysis of system features. It conducts a three-level coupling analysis at the system, task, and personnel levels. Through subjective analysis, quantitative calculation, and physiological response analysis, it accomplishes steps such as system feature analysis, task collection and dimension reduction, and task event extraction to achieve task convergence.
After completing the extraction of primary tasks through the aforementioned steps, it needs to conduct a comprehensive analysis by integrating conceptual tuple frameworks. This methodology defines five key components: task objectives, task sets, task sequences, display and control variables, and influencing factors. The analysis systematically examines five dimensions: task decomposition and composition, temporal execution flow, conditional constraints based on dependent variables, and external influencing factors. By identifying critical implementation checkpoints, this approach establishes a robust foundation for task modeling and process optimization.
The task modeling layer visually presents the five conceptual elements through a graphical representation. It establishes standardized graphical modeling methods to visually demonstrate the system’s task architecture, workflow processes, and interaction relationships. Creating a unified graphic symbol library, it establishes connections between different types of conceptual elements and graphical components. Through visual modeling, complex task logic is transformed into clear graphical expressions, enabling stakeholders to quickly grasp the system’s overall architecture. This approach also provides intuitive task model references for subsequent HCI interface design.
3.1.2. Technology Implementation Path
The task modeling process follows the linear execution flow illustrated in Figure 6. After four rounds of subjective and objective dimension reduction calculations, the task achieves convergence, and the key tasks of the complex system are extracted. This process involves the knowledge of researchers and experts, algorithmic computation, and analysis of physiological patterns. Through the integration of qualitative and quantitative analyses, it collectively derives key mission scenarios for complex systems using the concept of the tuple analysis method to analyze the main task scenarios and the subtask patterns of each task. After standardizing the visual elements of the model, the main tasks are modeled and presented.
Figure 6.
The linear execution flow.
3.2. Task Extraction
3.2.1. System Composition Analysis
Industrial HMC systems are multidimensional complex systems integrating human resources, computing, networks, and physical environments [30]. The entire manufacturing lifecycle involves factors characterized by complexity and diversity. Key technologies encompass manufacturing engineering, machine intelligence, and human–machine collaboration. Core components include personnel, production equipment, sensors, industrial software, materials, semi-finished products, and finished products. These elements interact and support one another to accomplish manufacturing tasks for products of various specifications. The constituent elements belong to personnel systems, physical systems, and information systems. Through the organic integration and in-depth collaboration of communication technologies, computer technologies, and control technologies, industrial systems achieve real-time perception, dynamic control, and information services [31].
The human dimension describes the personnel involved in the manufacturing process, including production management personnel, technical R & D personnel, equipment maintenance personnel, production operation personnel, quality inspection personnel, procurement and sales personnel, etc. It involves the knowledge, experience, technology, behavior, and physiological data attributes of these personnel.
The physical dimension describes the flow and transformation of raw materials, sensors, actuators, semi-finished products, and finished products throughout the manufacturing process. Raw materials refer to the initial materials involved in production. Sensors and actuators vary depending on the product type and manufacturing process. For example, in metal rolling, key actuators include rolling mills, welding machines, uncoiler machines, tension rollers, and baling machines, while sensors consist of position detectors and weld seam inspection devices. Semi-finished and finished products refer to items that have been processed on the production line after initial manufacturing and final processing.
The information dimension encompasses both measurable static data generated by personnel, equipment, and environmental factors during production processes and dynamic information that evolves with manufacturing execution. This process involves data perception, acquisition, storage, and computation, and data visualization is achieved through industrial software interfaces. Key components include programmable logic controllers (PLCs), production monitoring and data acquisition systems, management systems, and human–machine interfaces. Personnel utilize the data provided by the software to perform critical operations such as real-time monitoring, control, troubleshooting, and emergency response.
Information systems serve as vital bridges connecting human systems with physical infrastructure, embodying the essence of digitalization, informatization, and intelligent development. They act as essential digital tools supporting smart manufacturing operations. The software components within these systems provide user interfaces that integrate production data visualization and physical system control channels. As the most user-engaged elements, they form the core components and primary interfaces of industrial human–machine interaction systems, as illustrated in Figure 7.
Figure 7.
Core interaction patterns of industrial HMC systems.
In information systems, the component that has the closest contact with users is industrial software. Operators use dedicated peripherals such as keyboards, mice, and joysticks to convert their commands into machine control signals, enabling the physical system to respond. Software interfaces typically include system menus, status bars, visual production line modules, control zones, and data display areas. These interfaces present real-time, dynamic, and complex information with diverse operational modes. See Figure 8.
Figure 8.
Industrial software interface.
3.2.2. Task Collection and Dimension Reduction
(1) Data acquisition
Task objectives encompass all responsibilities assumed by personnel involved in production activities and human–machine interaction processes. Through literature review and field investigations, we collaborated with operators and automation experts to understand the system’s operational status, evaluate the current state of industrial intelligence, and identify specific tasks carried out using industrial software.
Finally, we identified 47 tasks from interview transcripts, including:
- -
- Monitoring real-time production status via industrial software;
- -
- Tracking operational data from systems, equipment, and sensors;
- -
- Reviewing parameter configurations;
- -
- Adjusting operational modes;
- -
- Modifying production models;
- -
- Reviewing warning messages and troubleshooting recommendations;
- -
- Identifying abnormal targets;
- -
- Resolving anomalies;
- -
- Accessing historical production records;
- -
- Inspecting finished and semi-finished product information;
- -
- Comparing preset equipment parameters with actual performance;
- -
- Performing maintenance operations.
Experts were invited to preliminarily merge the tasks according to the correlation and obtain 17 main tasks, as shown in Table 1.
Table 1.
Main tasks from expert consolidation.
(2) Dimension reduction
To further refine the computational process, the aforementioned tasks were incorporated into a survey questionnaire distributed nationwide to industrial manufacturing personnel. The responses were organized using a 7-point Likert scale format.
In this experimental round, 135 questionnaires were distributed, and 126 valid responses were collected. Feedback from participants demonstrated that the questionnaire questions were well-designed and comprehensively covered the relevant tasks.
The survey participants represented diverse demographics in terms of gender, age, and job roles. The sample had a balanced gender representation, with 50.79% male and 49.21% female. Regarding age distribution, 58.73% of respondents were aged 31–40, followed by 24.6% in the 26–30 age bracket. Job classification showed that managers were the predominant group (57.94%), followed by software monitoring operators (16.67%), workshop production staff (13.49%), and automation developers (16.67%). In terms of tenure, 50% had 6–10 years of experience, and 26.19% had 11–15 years of experience.
To simplify the task structure, factor analysis was employed to reduce the dimension of questionnaire data. In this section, SPSS19.0 (IBM’s statistical software) was used to perform principal component analysis (PCA) on the dataset, extracting common factors for human–machine interaction tasks in industrial systems. Considering the independence between task factors, PCA combined with variance-maximizing rotation (Varimax, Baotou Iron and Steel Company, Baotou, China) was applied for factor extraction. Convergence was achieved after 18 iterations [32].
The Kaiser-Meyer-Olkin (KMO) test yielded a value of 0.807, indicating strong correlations among variables (p < 0.000). This confirms the suitability of the collected questionnaire data for factor analysis. Through iterative factor extraction experiments, combined with the scree plot and cumulative variance contribution analysis, the optimal solution was identified at six common factors, achieving 65.380% cumulative variance contribution. The rotated pattern matrix is presented in Table 2.
Table 2.
Pattern Matrix.
Factor 1 consists of three operational tasks: “controlling the actual operation of production lines via interface controls and buttons”, “selecting production models and adjusting production modes for the entire production line using interface controls and buttons”, and “modifying equipment functions and operational modes through interface controls and buttons”. These tasks indicate that operators adjust production models, system/subsystem configurations, and equipment/subequipment operation modes via industrial software interfaces. Since all three tasks are related to control execution tasks, this factor is named “Control execution task”.
Factor 2 comprises five operational tasks: “monitoring production status through graphical production lines”, “accessing real-time sensor data”, “viewing live operational metrics of production lines”, “analyzing real-time system/subsystem performance”, and “tracking critical equipment status”. These tasks are all closely integrated with operators’ real-time monitoring of production lines, systems, subsystems, equipment, and sensors via industrial software, collectively referred to as the “Production monitoring task”.
Factor 3 comprises three tasks: “reading product-related data from the table”, “viewing preset parameter values of important equipment”, and “inquiring and communicating about production conditions”. These tasks involve communicating with operators after querying information via the industrial software interface, so they are named “Communication task”.
Factor 4 consists of two components: “Abnormal Alert Handling Suggestions” and “Abnormal Information Warnings”, both of which pertain to production anomalies. Therefore, it is called the “Abnormal Issue Handling Task”. This factor refers to the industrial software’s alert notifications and handling recommendations for abnormal situations.
Factor 5 consists of two components: “Display and Comparison of Equipment Preset Parameters with Actual Operational Data” and “Historical Production Information Storage and Query”. These tasks employ bar charts, line charts, and other visual formats to help operators make informed decisions via comparative analysis and trend assessment. Therefore, they are labeled as “Comparison and Review Task”.
Factor 6 consists of two components: “Integrating visual symbols, text, and numerical data to present production line information” and “Displaying such information through universally understandable graphic symbols”. These elements relate to graphical and symbolic production line presentation methods and data retrieval processes. Thus, they are designated as “Symbol Reading Task”.
(3) Task attribute quantification
The Kano model was employed to quantitatively analyze the functional attributes of the six task factors. Through the Kano model questionnaire, we examined users’ attitudes toward industrial software in both positive and negative dimensions when the software provides or fails to provide specific task functionalities. This survey consisted of 4 basic information questions and 12 task-related questions (6 positive and 6 negative dimensions). Targeting industry professionals via an online survey platform, 84 questionnaires were distributed nationwide to individuals working in industrial manufacturing monitoring and complex operation software roles, and 81 valid responses were collected. Task attributes were quantified using the Better-worse algorithm to identify task positioning within attribute quadrants. The calculation formula is as follows:
In the formula, M means required attributes, O means expected attributes, A means charismatic attributes, and I means unimportant attributes. Through the analysis and calculation of the task attributes, the six task attributes are shown in Table 3.
Table 3.
Task Factor Classification Using the KANO Model.
Figure 9 illustrates the distribution of six task factors across the Better-worse coefficient quadrant. Monitoring production and information queries are key tasks in human-industrial software interactions, having the greatest impact on operators. They are followed by control execution and anomaly resolution tasks. The comparison view and multi-display mode are considered attribute tasks with no significant differences.
Figure 9.
Better-worse Distribution.
The experimental results revealed no significant differences in task attributes between the comparison review task and the graphic symbol reading task, indicating that both tasks were evaluated as having relatively low importance. This narrowed the scope of the six task factor categories to four primary types. Among these, monitoring, communication, and control tasks were prioritized over anomaly issue-resolution tasks.
(4) Task event division based on natural eye movement behavior
A task event refers to a collection of task sequences that achieve specific objectives within a given context. These events can serve as independent descriptive primitives to establish connections with other tasks. Due to their autonomy, task execution naturally triggers unique physiological signal patterns.
This study utilizes eye-tracking technology to observe industrial software operators in real workshop monitoring environments, tracking their natural eye movements while performing four core tasks: monitoring, control execution, communication, and anomaly resolution. By collecting eye movement data during software operation, the research identifies that tasks sharing similar behavioral patterns belong to the same event category, while distinct events exhibit differentiated eye movement metrics. Through eye-tracking visualization, the study analyzes variations in eye movement patterns.
The desktop eye tracker was positioned centrally below the monitor. The Tobii Nano Pro desktop eye tracker (60 Hz sampling rate) was used, with the scene software shown in Figure 8. Eye-tracking materials for the four task categories were sourced from industrial production monitoring software developed by Hitachi, which was implemented in a certain Iron and Steel Company’s intelligent steel rolling production line in China.
To ensure adequate physiological signal induction for observers under natural production conditions and achieve sufficient task type coverage, while facilitating task-related eye movement data labeling during processing, this experimental design collects task-related eye movement data by having staff members watch typical task operation interface videos. The videos are captured from the production interface screen recordings. After expert verification, the video content corresponds to the task type.
The experiment participants were workshop production monitoring personnel, and there were two participants. Both had extensive experience in production monitoring and using experimental software.
The study examines the horizontal (x) and vertical (y) positions of fixation points and instantaneous gaze points, analyzes eye movement speed metrics to identify differences in eye movement patterns across tasks, and identifies typical eye movement pattern characteristics. Time-scale segments (horizontal axis) and absolute vertical axis segments of pattern features are extracted, with the visualization of these metrics shown in Figure 10.
Figure 10.
Visualized eye movement patterns across four tasks: (a) Subject 1; (b) Subject 2. Note: In the figure, the blue line represents the horizontal position of the instantaneous gaze, and the yellow line represents the vertical position of the instantaneous gaze. The wider blue line indicates the horizontal position of the gaze behavior, while the wider yellow line indicates the vertical position of the gaze behavior. The purple line represents the eye movement speed.
The dynamic eye movements of two participants reveal that the instantaneous fixation positions during monitoring tasks exhibited significant horizontal and vertical variations. This indicates that the visual focus of the task covers the entire monitoring interface.
In contrast, control execution tasks, communication tasks, and complex problem-solving tasks displayed localized fixation patterns. This suggests that these tasks rely on stable interface functional modules. Post-interview analysis confirmed that control execution tasks predominantly utilize centralized button operations in the control module area, while communication tasks primarily depend on the text and numerical information displayed in the table section of the interface.
In terms of fixation points, Task 1 has a scattered fixation area, while Tasks 2 and 3 have a more concentrated fixation area. This clarifies the main functional modules corresponding to the tasks and provides a basis for the design of task-based evocative materials.
In terms of eye movement speed, production monitoring and communication tasks exhibit significantly lower eye movement rates, while control execution and anomaly handling demonstrate higher rates. This indicates that these task behaviors require rapid eye movements to locate targets and perform operations, suggesting higher task demands for the latter two categories. Research shows that eye movement speed correlates positively with cognitive load, indicating that these tasks involve more scenarios requiring cognitive load management and fine-grained intention pattern analysis.
The instantaneous gaze positions and fixation points in complex problem-solving tasks involve multiple regions with significantly different spatial distributions, which allows for more detailed task event categorization. Post-event interviews with monitoring personnel validated the experimental findings: complex problem-solving tasks are highly correlated with the monitors’ knowledge, experience, and skills, involving intricate cognitive processing and multiple cognitive stages.
Conventional execution paths engage multiple functional areas, covering task units beyond the aforementioned three categories, thus constituting composite task types. Due to the lack of distinct separable patterns from other tasks, they are not considered typical candidates for further interactive task modeling.
At this point, the industrial HMC tasks related to fine-grained intention are further narrowed down to task 1: monitoring production task and task 2: communication task.
3.3. Different Pattern Analysis Within Tasks
In the context of digital, information-based, and intelligent manufacturing, monitoring automated production lines serves as a critical basis for assessing production status and making scientific decisions. It is a prerequisite for safe and efficient production and the foundation for preventing major accidents. By inspecting, surveilling, and controlling the monitored objects, this monitoring task effectively enhances production efficiency and product quality, representing a primary human–machine interaction scenario in industrial systems.
According to different production scenarios, there are two types of task units for production task monitoring, corresponding to refined task modes. They are the visual browsing mode of the monitor in normal production scenarios and the target search mode of the monitor in abnormal production scenarios, as shown in Figure 11.
Figure 11.
Monitoring production task and fine task pattern.
In normal production scenarios, monitors carry out routine monitoring tasks by extracting target elements such as the entire system, subsystems, equipment, and sensors to analyze production conditions. During abnormal production situations, monitors conduct browsing and troubleshooting through real-time data analysis and comparison of production data with preset parameters to identify anomalies. Subsequently, human intervention is employed for resolution.
Communication tasks occur between personnel at the control and execution layers. While execution layer personnel have real-time yet transient access to production site conditions through immediate signals, control layer personnel can retrieve sensor data via industrial software interfaces. This includes system and equipment parameters, real-time operational data, and product data—information that is delayed but long-term. The information held by these two groups exhibits differences in granularity, credibility, transparency, and asymmetry, as illustrated in Figure 12.
Figure 12.
Communication task and fine task mode analysis.
Information retrieval and interaction between control-layer personnel and executive-layer personnel primarily rely on data sources provided by industrial software. The information to be verified typically includes preset process parameters and real-time operational data. This information is generally presented through graphical symbols, textual symbols, numerical symbols, or combinations of these formats.
For complex human–machine interfaces, tabular data serves as the most common information organization format. Another approach combines tabular data with visual graphics and other modalities, such as displaying near production line systems, equipment, or sensors to facilitate real-time interpretation of production status.
Based on differences in operator interpretation behaviors caused by presentation formats, communication tasks are further categorized into tabular communication and multimodal information communication.
3.4. Interaction Model Construction
Analyze the detailed patterns of the above two tasks using the task concept meta-analysis method. After comprehensively analyzing the task objectives, sets, sequences, display control variable properties and influencing factors, model the task visually. The graphic elements in the model are standardized as shown in Table 4:
Table 4.
Model Diagram Meaning.
The standardized graphics are combined with the task concept meta to visualize the task model. The system interaction task model is built around the two main types of HMC tasks in the industrial system, as shown in Figure 13.
Figure 13.
Industrial HMC Interaction Model.
4. Materials and Methods
4.1. Experimental Procedure
Based on the two types of task intentions with fine-grained intention patterns proposed, an EEG experiment was designed. The materials used in the intention-evoking experiment were all taken from the interface of the automatic production line’s supporting industrial software of the factory (Baotou Iron and Steel Company, Baotou, China). To avoid redundant stimulation, the interface was processed as a prototype interface.
The task model reveals that Task 1 exhibits two distinct fine-grained intention patterns: visual browsing under normal conditions and target search under abnormal conditions. Visual browsing refers to the aimless, generalized scanning by monitors. In the experimental design, participants must maintain continuous monitoring throughout the task period for a specified duration. To ensure that participants generate task-related EEG signals, they are required to diligently complete two tasks after the monitoring ends, which evaluates the task execution quality.
For the purposeful target search intention experiment, participants must sustain focused target search during task execution. Drawing from Liang et al.’s complex multitasking system paradigm [21] featuring target search subtasks, the experimental procedure is structured as follows: First, participants receive target requests, visually search for corresponding targets, verify if the number of identified targets matches the given quantity, and provide key feedback. The experimental flow is illustrated in Figure 14.
Figure 14.
EEG experimental protocols for task 1.
The communication task patterns emerge from interaction scenarios and presentation modalities. They include tasks such as reading table information and providing responses, as well as processing multimodal data (combining tables, production lines, symbols, and text) to formulate answers.
Participants receive communication requests, clarify their objectives, locate target objects within the data presented in tables, and ultimately provide responses. The experiment requires setting up a sufficient number of verifiable table objects and preparing communication questions to keep participants continuously engaged in the communication request-response cycle.
The multimodal communication experiment involves participants receiving requests and responding via a multimodal interface that integrates tables and visual production lines, combining information from both modalities. When encountering abnormal data, participants visually locate the corresponding equipment positions on the dynamic production line. The experimental procedure is illustrated in Figure 15.
Figure 15.
EEG experimental protocols for two types of fine-grained intentions in communication tasks.
The detailed intention experiment was programmed using Tobii Pro Lab software (Version 1.241.54219, x64). The procedure commenced with the experimenter explaining the process, after which participants logged into the computer and completed a pre-experiment. Once confirmed as ready, participants initiated the experiment by pressing the space bar.
The procedure starts with the recording of resting-state EEG signals. Participants then undertake two sub-experiments under the monitoring production task, followed by two sub-experiments under the communication task. Before each experimental task, the instructions for the current task are displayed. Participants can initiate the task by pressing the spacebar once they are prepared.
The EEG annotation system is pre-configured in the software, which automatically marks physiological signals at both the beginning and end of each task. After finishing a task, users can take a rest and resume the experiment by pressing the space bar when they are ready. The system records resting-state EEG data and captures two distinct EEG patterns for fine-grained intention classification during the execution of two types of tasks.
4.2. Experimental Environment
This experiment utilized Brain Products’ EEG amplifiers and a 64-electrode cap to collect the participants’ brainwave data. The data was sampled across cortical channels using the international 10–20 lead system, with the TP9 and TP10 electrodes serving as reference points. All impedance measurements remained below 5 kΩ, and the sampling rate was set at 1000 Hz.
A Tobii Pro Nano eye tracker was employed to verify the induction of fine intention patterns. Two Lenovo desktop computers were used: one for data acquisition and recording, and the other for running experimental programs.
The participants completed tasks using a mouse and keyboard while seated approximately 60 cm from the screen. Twenty participants took part in the experiment, and all equipment specifications and setup details are shown in Figure 16.
Figure 16.
Experimental scenario: (a) Experimental data acquisition channel points; (b) experimental scenario and BP EEG Signal Collector; (c) eye tracker.
4.3. Validity Verification of EEG Data Set
It is challenging to verify whether participants accurately provided EEG data that reflects their intention patterns during experiments. To address this issue, the experimental design integrated post-task performance evaluation with eye movement data collection, ensuring that the EEG data used in subsequent analyses was strongly correlated with task performance.
4.3.1. Performance
In terms of task performance, most of the 20 participants successfully comprehended the requirements and completed the tasks assiduously. Notably, 18 participants attained 100% accuracy in answering questions during the visual scanning task. Participants 4 and 6 each made one error, leading to a 50% accuracy rate. Through post-experiment follow-up interviews and retrospective analysis of video recordings, researchers confirmed that both participants understood the experimental requirements and attentively monitored the task throughout. Subsequent inquiries disclosed that their errors originated from misunderstandings of the test questions and insufficient review of answer options. Therefore, neither participant was excluded from the study.
4.3.2. Eye Movement Behavior Analysis
Eye-tracking technology was employed to analyze the participants’ eye movement patterns during task execution, including fixation duration, saccade speed, and gaze trajectories. This enabled the evaluation of whether the participants’ intention states aligned with the experimental requirements and whether EEG patterns could be utilized for subsequent fine intention modeling.
Through visual analysis of the eye movement data, we examined fine intention execution from three perspectives: (1) cumulative fixation duration heat maps, (2) saccade path analysis, and (3) gaze trajectory monitoring. The findings revealed the following insights.
For Task 1, a visual mode comparison between Figure 17 and Figure 18 reveals that visual browsing tasks exhibit an extensive distribution of fixation points, predominantly concentrated on graphic symbols along the production line. The scanning paths show random full-screen scanning trajectories.
Figure 17.
Cumulative heat map: (a) Visual browsing pattern; (b) visual search pattern.
Figure 18.
Cumulative scanning path map: (a) Visual browsing pattern; (b) visual search pattern.
In contrast, visual search tasks demonstrate concentrated fixation points in two primary areas: the search target region in the upper right corner and graphic elements across the production line. Although search tasks involve fewer fixation points than browsing tasks, the majority of these points occupy larger areas, indicating longer fixation durations. The scanning paths in search tasks frequently cross multiple regions and extend further, yet they maintain clear patterns.
This confirms that participants maintain a certain level of goal orientation during the browsing process.
For Task 2, as shown in Figure 19 and Figure 20, during the cumulative task duration, the table-based tasks demonstrated a more concentrated gaze distribution pattern. Specifically, attention was focused on the headers of both rows and columns, as well as the locations of numerical values in the experimental tasks. The scanning paths were widely spread, with trajectories mainly ending at the headers of the table rows.
Figure 19.
Cumulative thermal map: (a) Table communication pattern; (b) multimodal information communication pattern.
Figure 20.
Cumulative scanning path diagram: (a) Table communication pattern; (b) multimodal information communication pattern.
The fixation point distribution in multimodal communication tasks exhibits concentrated patterns, mainly focusing on two areas: the visual production line and the table. Regarding cumulative scanning paths, both task types display scanning trajectory patterns consistent with the experimental requirements. For example, in the table communication task, the connections of fixation points predominantly cluster between the header and data sections of the scanning trajectory. In contrast, the multimodal information communication task shows fixation point connections that bridge the visual production line and the table display modes, indicating eye movements between these two visual domains.
The results showed that the fixation position, fixation trajectory, fixation time, and scanning path of the 20 subjects in this round of experiment were highly consistent with the experimental task setting, indicating that the subjects performed the task well. The collected EEG signals were correlated with fine intention and could reflect the EEG feedback under fine intention.
4.4. Data Description and Preprocessing
The raw EEG data was preprocessed using the EEGLAB toolbox in Matlab R2013b. The workflow consisted of electrode localization, exclusion of active electrodes, band-pass filtering (0.5–45 Hz), data slicing, artifact removal, and re-referencing using the TP9 and TP10 electrodes, which left 61 remaining channels. ICA algorithms were utilized to eliminate artifacts like blinking, ECG, and eye movement, and outliers were removed at ±100 μV. A subject-wise approach was adopted to construct multi-subject training sets and leave-one-subject test sets.
4.5. Improved Algorithm
Phase Locking Value (PLV) quantifies the phase consistency between two signals over time, with values ranging from 0 to 1 [33]. MSPs-PLV is an enhanced method for multi-channel electrode phase synchronization. The preprocessing EEG signals undergo Hilbert transform to extract phase values, which are then used to calculate phase synchronization between electrode pairs across multiple channels. The most synchronized electrode pairs are selected, and their PLV values form a feature space. Machine learning classifiers are then applied to categorize implicit intentions. The workflow is illustrated in Figure 21.
Figure 21.
Schematic illustration of MSPs-PLV feature extraction. Note: The yellow-marked channels represent the selected synchronous channel pairs. The darker the color, the stronger the synchronization, and the PLV value approaches 1.
The specific steps of this method are as follows:
4.5.1. Calculate the Phase-Locking Value (PLV) Between Channels
The PLV quantifies the synchronization of two signals’ phases, reflecting phase consistency across channels and brain regions. In this study, we analyzed the phase synchronization patterns of EEG signals across channels to identify distinct intentional EEG synchronization modes.
The calculation process is as follows:
For an EEG signal sequence in a specific , use the Hilbert transform to find the imaginary part of the corresponding complex signal . The original signal after inversion can be expressed as:
Use the arctan function to calculate the instantaneous phase , obtain the phase difference between the two signals by combining the instantaneous phase and amplitude of the complex signal.
Compute the unit-modulus signal on the complex plane and then calculate the mathematical expectation of the temporal values. The calculation formula is as follows:
The PLV value ranges from 0 to 1. A value closer to 1 indicates better phase synchronization between the two signals, while a value closer to 0 indicates worse synchronization.
4.5.2. Select Most Significant Pairs (MSPs) with the Maximum Difference
To classify intents, we calculate the difference between channel pairs of two intent categories and select MSPs with the largest differences as dimensions for intent feature construction. Fifteen pairs of MSPs are extracted from each frequency band, as shown in Figure 22.
Figure 22.
The electrode pair with the greatest PLV difference identified through two fine intention searches in Trial 14’s monitoring production task is shown as an example.
Assume two fine-grained intention patterns and N-channel EEG signals. Each pair of PLV channels can be represented by a matrix:
indicates the PLV value between channel i and channel j under intention 1. indicates the PLV value between channel i and channel j under intention 2. means a difference in PLV values for the channel pair under the two types of intentions. represents the PLV value between channel i and channel j under intention 1. N is the total number of channels.
For each channel pair, calculate the PLV difference between the two types of intent:
Identify the MSPs with the largest PLV difference among all possible channel pairs. Specifically, the task is to determine:
The dimension will be constructed as an intention feature. The final intention phase difference can be expressed as:
4.5.3. Reconstructing Intention Features Using MSPs
To expand the model training dataset, we partitioned the intent task state samples into time windows with 1-s interval and no repetition. For each intent category, we extracted 15 pairs of MSP channels with the maximum difference and calculated the corresponding MSPs for each intent category.
The calculation formula is as follows:
Let represent the channels between the i-th intention and the j-th intention. For the i-th intention, we need to aggregate its MSPs channel pairs with those of other intentions. Let denote the complete set of MSPs channel pairs for the i-th intention, which can be expressed as:
where represents the union of sets.
Next, the PLV is extracted from the intention feature set. Let represent the phase locking value feature of the i-th channel pair for the j-th intention. For the i-th intention, extract the phase-locking value characteristics of all channel pairs in . Let represent the complete feature vector of the i-th intention, which can be expressed as:
Among them, 1 to 15 represent 15 pairs of channels for the first intention.
The schematic diagram of feature construction is shown in Figure 23:
Figure 23.
Schematic diagram of feature construction.
4.6. Model Data Construction
To prevent data leakage, the subject-wise approach was employed to construct training and test sets. Parameter optimization was performed using 5-fold cross-validation and grid search to determine the optimal c and g values for the RBF-SVM model. Given SVM’s high requirement for sample balance, this study employs the SMOTE technique to equalize sample quantities across different class labels. The final training and test set sizes for each inter-subject modeling experiment are presented in Table 5.
Table 5.
Sample capacity of train and test sets.
5. Results and Discussion
5.1. Algorithm Performance
This study included 20 participants to evaluate the recognition performance of two fine-grained intention patterns: visual browsing/target search and table communication/ multi-modal information communication, as shown in Table 6.
Table 6.
The performance of the method.
The two types of fine-grained intent recognition models achieved an average accuracy rate exceeding 96% across both training and test sets. In the monitoring production task, the training and test accuracies for the two fine-grained intents were 99.54 ± 1.14% and 99.42 ± 1.42%, respectively. For the communication task, the accuracies reached 99.91 ± 0.32% and 99.88 ± 0.46%. The method proposed in this research demonstrates exceptional accuracy in fine-grained intent pattern recognition, with its small standard deviation further validating its generalization performance. A small standard deviation indicates that the MSPs-PLV feature’s inherent cross-subject stability is naturally or through preprocessing normalized to a common scale and individuals exhibit high consistency in their optimal decision boundary.
The table presents the optimal coefficients c and g of the Gaussian kernel function RBF-SVM determined through grid search after training. In the production monitoring task for fine intention pattern recognition, the average coefficients are c = 0.48 and g = 0.76, while in the communication task, the average coefficients are c = 0.03 and g = 0.57. The consistency of parameters c and g proves that there are no fundamental differences in the feature space regarding which RBF kernel width and regularization parameter to use in which interval. Their separability and margin are highly similar. This demonstrates well-controlled experimental conditions, providing a basis for cross-species recognition. Using these parameters to train a leave-one-subject-out (LOSO) general SVM can prevent performance collapse caused by hyperparameter drift.
5.2. Baseline Method Comparison
The baseline comparison method is the traditional PLV method, while integrating it with the aforementioned RBF-SVM. The performance of each method in the frequency domain was observed. The three baseline methods for comparison are:
(1) The traditional PLV method;
(2) The traditional PLV in the frequency domain (FDPLV);
(3) MSPs-PLV in frequency domain (FDMSPs-PLV);
Comparison results are shown in Figure 24.
Figure 24.
Comparison of results with the baseline methods.
The experimental results show that the feature information enriched by frequency segmentation cannot improve the recognition accuracy, and the whole frequency band of PLV features has better discrimination ability for implicit intention.
The MSP method, which identifies electrode pairs with maximum PLV differences for constructing fine-grained intention features, outperforms traditional PLV algorithms. While frequency-domain PLV under the same feature screening method does not provide richer feature information, it still demonstrates higher recognition accuracy and smaller standard deviation compared to the two conventional time-domain PLV methods.
Figure 24 comprehensively demonstrates the high performance and stability of the MSPs-based approach in fine-grained intention pattern recognition across two task categories.
5.2.1. Comparative Analysis of Methods for Task 1
The recognition model developed using time-domain PLV based on MSPs achieved 99.42% accuracy, outperforming frequency-domain PLV’s 91.25% by 8.17 percentage points. In contrast, the traditional time-domain PLV algorithm (before optimization) recorded 86.08% accuracy, surpassing frequency-domain PLV’s 83.13% by 2.95 percentage points. See Table 7.
Table 7.
Method comparison for Task 1.
The experimental results demonstrate that the fine intention pattern features of electrode pairs selected by the MSPs method significantly outperform those of traditional multi-electrode pair PLV algorithms.
Figure 25a compares the accuracy of four recognition models across 20 experimental groups. The MSP-based feature space construction method for synchronous electrode pairs demonstrates significantly better performance than the traditional PLV method in both recognition accuracy and stability.
Figure 25.
Subject-wise test Acc and Difference test: (a) Subject-wise modeling results for 20 groups; (b) Friedman’s test result. The blue line represents the method of this paper. Note: The vertical axis indicates: 1 for the proposed method MSPs-PLV, 2 for FDMSPs-PLV, 3 for PLV, and 4 for FDPLV.
We conducted a Friedman’s nonparametric test on the identification accuracy rates of 20 experimental groups across four methods to determine if statistically significant differences existed. The p-value of 2.75 × 10⁻⁶ (significantly lower than 0.001) led to the rejection of the null hypothesis that all methods had identical accuracy rates, indicating substantial differences in identification performance.
The post hoc test using pairwise comparisons revealed that, as shown in the Friedman test plot, the proposed algorithm did not overlap with the other three algorithms, while the latter exhibited mutual overlaps. This demonstrates the superiority of our method over the three alternatives. There were no significant differences in recognition performance among the three alternatives, as illustrated in Figure 25b.
5.2.2. Comparative Analysis of Methods for Task 2
In the task of fine-grained intent recognition from multimodal information communication in tables, our method achieves the highest recognition accuracy (99.88 ± 0.46%) and value compared with the other three methods. See Table 8.
Table 8.
Method comparison for Task 2.
The frequency-domain phase synchronization features failed to provide sufficient discriminative characteristics for this classification task. Both frequency-domain PLV methods performed worse than time-domain approaches. The recognition accuracy of these two PLV methods in the frequency domain was only 86.08% and 83.00%, respectively, significantly lower than that of the time-domain MSPs-PLV algorithm (99.88%) and the PLV algorithm (89.60%).
As shown in Figure 26a, the comparison of the test accuracy rates of the four methods in the identification model of 20 groups of experiments shows that the method based on MSPs screening synchronous electrode pairs to constitute the feature space is significantly better than the other three methods in terms of identification accuracy and stability.
Figure 26.
Subject-wise test Acc and Difference test: (a) Subject-wise modeling results for 20 groups; (b) Friedman’s test result. The blue line represents the method of this paper. Note: The vertical axis indicates: 1 for the proposed method MSPs-PLV, 2 for FDMSPs-PLV, 3 for PLV, and 4 for FDPLV.
The Friedman’s non-parametric test was employed to determine whether there were statistically significant differences in the accuracy of the four methods for fine intention pattern recognition. The test yielded a p-value of 1.36 × 10⁻⁵, which is below the 0.001 threshold. This result rejects the null hypothesis that all four methods have identical recognition accuracy, thereby indicating significant differences in performance.
We conducted pairwise comparisons among the four methods. The post hoc test results, as shown in Figure 26b (Friedman’s test plot), revealed no overlapping regions between our method and the other three approaches, indicating that our method significantly outperforms them in recognition performance. The overlapping regions among the other three methods suggest that there are no significant differences in their recognition performance.
5.3. Discussion
5.3.1. MSPs-PLV Characteristics Identified by Visualization
Twenty participants were assigned 15 pairs of MSP channels each to a 61 × 61 EEG coordinate system. The study examined the similarities and differences between major intention categories and fine intention patterns within tasks. The comparison results are shown in Figure 27.
Figure 27.
Most significant feature channel of 20 subjects: (a) Task 1; (b) Task 2. Note: To distinguish them, the MSP channels of 20 subjects are labeled with different colors.
The channel pairs of 20 screened subjects were displayed in different colors, revealing that MSPs screening exhibited individual specificity: each subject’s 15 pairs of MSPs differed. During training, the personalized PLV values of each subject’s MSPs channel pairs were used to form intention features.
By comparing the MSPs diagrams of production monitoring and communication tasks, we observe that the MSPs of the same subjects vary across different tasks. The distribution of MSPs exhibits significant differences between these two task categories. This indicates that feature selection based on MSPs in fine intention modeling should be determined by the broad category of interaction tasks. Different task types lead to distinct pairs of phase-synchronized channels even among the same subjects. In practical applications, fine intention recognition should be built on the foundation of broad task category intention recognition, using a two-tier cascade model approach for identification.
5.3.2. Functional Connectivity Analysis
The FieldTrip [34] toolkit was employed for brain power source localization. For volume conductor modeling, the standard BEM head volume conductor model provided by FieldTrip was utilized. Source space definition and lead field matrix calculation were subsequently performed, where potential neural activity sources in the brain were modeled as equivalent current dipoles. The theoretical potential distribution generated by each equivalent current dipole at all EEG electrode positions constituted the numerical solution of the EEG forward problem. Based on the obtained lead field matrix, the linearly constrained minimum variance (LCMV) beamformer algorithm was applied for source activity estimation [35]. According to the AAL atlas [36], the time series of source current density from the estimated 1149 dipoles were assigned to their corresponding 76 brain regions. The singular value decomposition method was then employed to extract the most representative source activity time series for each brain region.
The brain regions with phase synchronization are observed by tracing the intention patterns in two key task scenarios, and the functional channels that constitute the real-time flow or integration of information are observed.
The paired T-test [37] was employed to identify statistically significant functional connectivity subnetworks, detect phase synchronization differences across broad frequency bands, and trace brain origins of significantly different frequency bands. The thresholds used were Edge p < 0.005 and Component p < 0.05, with 10,000 permutation trials. The specific procedures were as follows:
- -
- First, conduct paired T-tests on each edge in the functional connectivity network, identifying edges with Edge p < 0.005 as candidate differential edges.
- -
- Based on the principle of connectivity, the candidate difference edges are divided into different network components (subnetworks).
- -
- Calculate the size of each network component, that is, the number of connected edges contained in each subnetwork.
- -
- To determine the significance of network components, we conducted 10,000 permutation tests to construct the empirical null distribution of maximum component sizes under random grouping. If a component size exceeds the 95th percentile of the maximum observed sizes from these tests (i.e., Component p < 0.05), the component is considered statistically significant between the two groups.
(1) Target searching pattern (Pattern 1) vs. Visual browsing pattern (Pattern 2)
Statistical analysis revealed statistically significant differences between the two patterns in the connection strength of PLV pathways, as illustrated in Figure 28; the related data is listed in Table 9.
Figure 28.
Connected edge diagram with significant differences for Task 1’s two patterns (t-value): (a) significant edge connection; (b) link strength. The name of brain regions is derived from the AAL atlas.
Table 9.
The brain region with the strongest phase synchronization between intention patterns for Task 1.
The red edge connection involved the primary node locations, such as the Superior Frontal Gyrus, Cuneus, Inferior Frontal Gyrus, Middle Cingulate Gyrus, etc. These brain regions are involved in working memory, attention regulation, higher cognitive control, visual attention, and visual information integration. The synchronous enhancement in these brain regions indicates a wide range of functional coordination and information exchange. Pattern 1 induced broader synchronization because it has more red connecting edges. It suggests that pattern 1 demands higher cognitive resource with enhanced phase locking and involvement of attention, memory, and cognitive control.
The blue connecting edges indicate brain regions where pattern 2 surpasses pattern 1. The brain region distribution in Figure 28 suggests that pattern 2 relies more heavily on the selective allocation of visual attention and the priority processing of visual information. The two brain regions with significant connectivity (ORBsupmed.R-MOG.L) are involved in value assessment and higher visual processing, visual-spatial integration, and visual-cognitive information integration, respectively. This transhemispheric and trans-network-phase synchronization is a crucial neural mechanism for visual-cognitive integration. It shows that the monitoring task calls for visual browsing and cognitive integration. These results suggest distinct task-related information routing strategies and may reflect a central–peripheral attentional reallocation mechanism.
The group average of functional connectivity strength of 20 subjects is shown in Figure 29. The results show that the functional connectivity of the brain regions in pattern 1 is stronger than that in pattern 2, with more significant task states and stronger phase synchronization between brain regions.
Figure 29.
Group average connection diagram for Task 1: (a) pattern 1; (b) pattern 2.
(2) Multi-modal information communication pattern (pattern 1) vs. Table information communication pattern (pattern 2)
The most synchronized brain region nodes under the two patterns are shown in Table 10. As shown in Figure 30, the two intention patterns of Task 2 were traced to functional connections involving the central prefrontal cortex, superior parietal cortex, superior frontal cortex, inferior frontal cortex, angular gyrus, insula, central posterior cortex, anterior cingulate cortex, and middle cingulate cortex, forming a complex frontal–parietal–lobal system network.
Table 10.
The brain region with the strongest phase synchronization between intention patterns for Task 2.
Figure 30.
Connected edge diagram with significant differences for Task 2’s two patterns (t-value): (a) significant edge connection; (b) link strength. The name of brain regions is derived from the AAL atlas.
The phase synchronization of the aforementioned brain regions suggests that communication tasks involve cognitive processes such as working memory maintenance and response inhibition, task switching and attentional balance, proprioceptive processing, as well as error monitoring and adaptive control. This indicates that in this communication task scenario, the operator requires efficient cross-network information integration, flexible task switching capabilities, and robust cognitive control reserves. The synchronization pattern reflects the high cognitive load of the operator in task 2.
More red edges indicate that pattern 1 has more extensive functional connections and information exchange than pattern 2. Through analysis of brain networks and functions, it demonstrates the integration of three major networks: the Executive Control Network (ECN), the Sensory-Motor Network (SMN), and the Salience Network (SN). Details include cognitive control–language execution–semantic integration; executive planning–sensory integration; conflict monitoring–cognitive control.
Pattern 2 shows a significant phase synchronization between two brain regions (ACG.L-DCG.R), which is a hemispheric coordination of the cingulate cortex. These two brain regions are associated with error monitoring and adaptive control, and their functional connectivity represents the integration of conflict detection and cognitive control.
The average group connectivity between patterns showed a large difference from task 1, as shown in Figure 31. But the difference in the average group connectivity within tasks was very weak, reflecting the similar physiological response of fine intention patterns and the difficulty of fuzzy classification.
Figure 31.
Group average connection diagram for Task 2: (a) pattern 1; (b) pattern 2.
5.3.3. Significance Analysis of Frequency Band Function Connection
NBS correction revealed a significant difference in only the gamma (30–45 Hz) frequency band connectivity between multi-modal communication and table communication, with the difference component being positive (indicating stronger connectivity under multimodal communication compared to tabular communication), at p = 0.043.
High-frequency functional connectivity indicates that multi-modal information communication demonstrates significantly stronger information integration compared to other tasks. It suggests that this task involves a high level of operator consciousness, potentially generating substantial cognitive workload. The edge connection of gamma-band communication tasks with significant differences is shown in Figure 32. This visualization displays the T-value distribution of statistically significant edges, where edge colors indicate T-value magnitudes. T-values > 0 indicate stronger multi-modal communication than tabular communication.
Figure 32.
Connected edge diagram with significant differences.
Further analysis revealed that most internal connections within this component were associated with SFGdor.R (Frontal Supramarginal Region, right dorsolateral prefrontal gyrus), indicating SFGdor.R as a key brain region for communication tasks. This region is typically considered part of the dorsolateral prefrontal cortex (DLPFC), which is involved in working memory, cognitive control, executive functions, attention regulation, decision-making, and understanding others’ intentions.
5.3.4. Cross-Domain Generalization Performance
The public intention EEG datasets are mostly coarse categories with significant physiological response differences, such as motor imagery intention datasets and cognitive task datasets [10]. This study conducted experiments based on the visual browsing intent experimental paradigm by Kang, Park et al., constructing a visual browsing intent dataset. Following the photo scenes from the original experiment, we carefully generated five similar scene photos using AIGC, designed the experimental procedure according to the paradigm, and collected EEG data. The experimental flow is shown in Figure 33.
Figure 33.
Baseline data set.
A total of five participants were enrolled in the study, and each completed two experimental sessions. Each session consisted of 10 trials (five trials for each of the two fine intention patterns). In the visual search task, the text was presented in ascending order to avoid the repetition of target items, thus eliminating the influence of prior experience on physiological signal induction. The 64-channel EEG data were collected using the Brain Product system at a 1000 Hz sampling rate. When applying the proposed method to this dataset, the experimental results are presented in Table 11.
Table 11.
Cross-scene generalization performance of the proposed method.
The proposed method achieves an accuracy rate of 85.09 ± 10.23% on the EEG dataset from this experiment, surpassing the 83.9 ± 0.07% result obtained by Park et al. in their single-modal EEG classification study.
Although the method’s accuracy (90.9 ± 0.07%) is lower than Park et al.’s implicit intention recognition approach that combines EEG phase synchronization and eye-movement multimodal features, it still shows 1.19 percentage points higher performance than their single-modal EEG modeling. This confirms the effectiveness of our method in fine-grained intention pattern recognition.
6. Conclusions
6.1. Main Work
This paper proposes a task modeling method for complex HMC, which includes task extraction, task analysis, and task visualization modeling. It integrates operators’ natural eye movement behaviors and multi-source heterogeneous data into the modeling process, making the model construction a repeatable process. The approach standardizes reliable input and execution methods while providing scientific foundations for optimizing HMC designs in complex industrial scenarios. In typical industrial HMC scenarios, we applied this method for task modeling.
This research also proposes a fine-grained implicit intention recognition method, which addresses the multi-channel functional connectivity characteristics of intentional EEG. Experimental results demonstrate that the MSPs-based PLV method outperforms both time-domain and frequency-domain PLV approaches in recognition accuracy. When applied to two typical industrial system-specific intention classification, the method achieves 99.42% and 99.88% accuracy rates, respectively.
By integrating functional connectivity sub-networks and brain source localization techniques with visualizations, this study employs multiple methodologies, including MSPs localization, PLV temporal dynamics, group-averaged PLV analysis, and functional connectivity tracing. The research precisely identifies task-specific frequency bands and key brain regions, while revealing functional connectivity differences and source activity variations between tasks and across patterns within tasks. Through visual analysis and differential verification, the study confirms the inherent ambiguity in fine-grained intention patterns and further validates the effectiveness of the proposed methodology.
6.2. Innovation
By taking human intention as our lens, we explore ways to weave human intelligence into HMC, fostering bidirectional perception and understanding that heighten information symmetry between the two agents and, ultimately, enhance overall performance.
The system-task-physiological multi-dimensional task-modeling framework overcomes existing limitations by incorporating physiological feedback and system-wide interaction characteristics. It effectively integrates multi-level information that combines subjective cognition, objective data, and physiological responses. The model achieves a leap from subjective requirements and functional descriptions to computable and verifiable task specifications, establishing a paradigm for extracting, analyzing, and modeling tasks in complex systems. This advancement drives the hierarchical convergence of industrial system interactions, enables concept-based tuple-driven task refinement, and provides reliable inputs for intention recognition.
This research refines the granularity of intention recognition technology, enabling more nuanced and precise interpretation of human intentions. The MSPs-PLV method addresses the limitations of existing methods by establishing a framework that identifies electrode pairs with maximum phase synchronization differences, enabling high-precision recognition of nuanced intention patterns. Furthermore, it reveals the neural mechanisms underlying these patterns through functional connectivity analysis, source localization, and identification of key brain regions and frequency bands.
6.3. Future Study
This research focuses on the transformation and upgrading of human-centered industrial systems in Industry 5.0, conducting experimental and exploratory studies on the theories and methods of integrating humans into intelligent systems. From the perspective of operators’ physiological signals, this paper presents a method for identifying refined implicit intentions. With the continuous development of technology, this research will play an increasingly important role in promoting the wide application of artificial intelligence technology.
Due to the limitations of research level, time, and laboratory conditions, this research still has certain limitations that need to be further explored and improved. The following aspects can be explored in future research work:
(1) The requirements for human physiological and cognitive state recognition in industrial human–machine collaborative scenarios are becoming increasingly stringent. The research mainly focuses on the recognition of operators’ implicit intentions. Further studies can be conducted on operator attention modeling, emotion computing, fatigue recognition, etc., and the methods proposed in this paper can be applied to other complex system fields for verification to improve the systematicness and reliability of the research structure.
(2) The sample size is limited, and most of the subjects are college students and young engineers, with a narrow distribution of age, educational background, and operational experience, and the generalization performance of the model still needs to be improved. All experiments (especially EEG experiments) were conducted in a controlled laboratory environment, lacking the noise, vibration, temperature and humidity changes, and multi-task parallelism of real workshops, which has not fully verified the robustness and reliability of the cognitive model in actual industrial scenarios. In future research, we will expand the physiological database by incorporating operators’ physiological data from various industrial scenarios, and further investigate the feasibility of combining the feature map proposed in this paper with deep learning models.
(3) Due to the interface conditions of the laboratory physiological sensing equipment, this study only achieves offline intent recognition, without achieving real-time online cognitive state assessment, failing to fully reflect the challenges of non-stationary noise, network latency, and sudden changes in task load in real industrial sites. The online effectiveness, timeliness, and long-term stability of the model have not been empirically verified. In addition, the hybrid intelligent system may introduce the risk of instability in the perception-decision-feedback loop, which needs to be evaluated and suppressed in future work.
In the future, the methods proposed in this paper will be further verified and optimized in diverse complex HMC systems, and problems will be identified in practical applications to continuously improve the theory. At the same time, the experimental paradigms for estimating human cognitive states in complex systems will be further optimized, the scale of the data set will be expanded, and the transformation of theoretical models to engineering-level applications will be promoted.
Author Contributions
Conceptualization, X.M. and W.H.; methodology, X.M.; software, X.M.; validation, X.M.; formal analysis, X.M.; investigation, X.M. and Z.L.; resources, X.M. and Z.L.; data curation, X.M.; writing—original draft preparation, X.M.; writing—review and editing, X.M., W.H. and Z.L.; visualization, X.M.; supervision, X.M., W.H. and Z.L.; project administration, X.M. and Z.L.; funding acquisition, X.M. and Z.L. All authors have read and agreed to the published version of the manuscript.
Funding
This research was funded by Metallurgical Engineering First-Class Discipline Scientific Research Special Project of the Department of Education of Inner Mongolia Autonomous Region China, grant number YLXKZX-NKD-024.
Institutional Review Board Statement
The study was conducted in accordance with the Declaration of Helsinki, and the protocol was approved by the Ethics Committee of Inner Mongolia University of Science ((2023) No.10) on 1 March 2023.
Informed Consent Statement
Informed consent for participation was obtained from all subjects involved in the study.
Data Availability Statement
The data used in this research can be downloaded from the following link, accessed on 1 February 2026: https://pan.baidu.com/s/1x_uPtkVBp0d_rRQuVFzY_w?pwd=0000.
Conflicts of Interest
The authors declare no conflicts of interest. The funders had no role in the design of the study; in the collection, analyses, or interpretation of data; in the writing of the manuscript; or in the decision to publish the results.
References
- Xu, X.; Lu, Y.; Vogel-Heuser, B.; Wang, L. Industry 4.0 and Industry 5.0—Inception, conception and perception. J. Manuf. Syst. 2021, 61, 530–535. [Google Scholar] [CrossRef] [Scilit]
- Moore, A.; O’Reilly, T.; Nielsen, P.D.; Fall, K. Four Thought Leaders on Where the Industry Is Headed. IEEE Softw. 2016, 33, 36–39. [Google Scholar] [CrossRef] [Scilit]
- World Economic Forum. Digital Transformation of Industries; World Economic Forum: Cologny/Geneva, Switzerland, 2016. [Google Scholar]
- Miller, D.; Sun, A.; Johns, M.; Ive, H.; Sirkin, D.; Aich, S.; Ju, W. Distraction Becomes Engagement in Automated Driving. Proc. Hum. Factors Ergon. Soc. Annu. Meet. 2015, 59, 1676–1680. [Google Scholar] [CrossRef] [Scilit]
- Bousdekis, A.; Apostolou, D.; Mentzas, G. A human cyber physical system framework for operator 4.0–artificial intelligence symbiosis. Manuf. Lett. 2020, 25, 10–15. [Google Scholar] [CrossRef] [Scilit]
- Liu, Z.; Lou, S.; Yixiong, F.; Song, X.; Tan, J. A closed-loop human-computer interactive design method based on sequential human intention prediction and knowledge recommendation. J. Eng. Des. 2024, 35, 1–24. [Google Scholar] [CrossRef] [Scilit]
- Wang, W.; Zhao, M.; Gao, H.; Zhu, S.; Qu, J. Human-computer interaction:Intention recognition based on EEG and eye tracking. Acta Aeronaut. Astronaut. Sin. 2021, 42, 292–302. [Google Scholar]
- Ma, L.S.; Lv, J.; Pan, W.J.; Shan, J.J.; Ping, Z.Q. Research on Implicit Intention Recognition and Classification Based on Eye Movement Pattern. J. Graph. 2017, 38, 332–340. [Google Scholar]
- Kitamura, Y.; Yamaguchi, Y.; Imamizu, H.; Kishino, F.; Kawato, M. Things Happening in the Brain While Humans Learn to Use New Tools. In Proceedings of the SIGCHI Conference on Human Factors in Computing Systems, Fort Lauderdale, FL, USA, 5–10 April 2003; Association for Computing Machinery: New York, NY, USA, 2003; pp. 417–424. [Google Scholar]
- Keirn, Z.A.; Aunon, J.I. A new mode of communication between man and his surroundings. IEEE Trans. Biomed. Eng. 1990, 37, 1209–1214. [Google Scholar] [CrossRef] [Scilit]
- Zheng, C.-J.; Xiao, G.-B.; Luo, T.-J. Improved deep neural network with overlapped time slice for pattern recognition of motor imagery EEG. Comput. Syst. Appl. 2022, 31, 52–64. [Google Scholar]
- Miao, X.; Hou, W. Human–Computer Interaction Multi-Task Modeling Based on Implicit Intent EEG Decoding. Appl. Sci. 2024, 14, 368. [Google Scholar] [CrossRef] [Scilit]
- Qu, J.; Guo, H.; Wang, W.; Dang, S. Prediction of Human-Computer Interaction Intention Based on Eye Movement and Electroencephalograph Characteristics. Front. Psychol. 2022, 13, 816127. [Google Scholar] [CrossRef] [Scilit]
- Park, U.; Mallipeddi, R.; Lee, M. Human Implicit Intent Discrimination Using EEG and Eye Movement. In Proceedings of the 21st International Conference on Neural Information Processing (ICONIP), Kuching, Malaysia, 3–6 November 2014; Springer International Publishing: Cham, Switzerland, 2014; pp. 11–18. [Google Scholar]
- Kang, J.S.; Park, U.; Gonuguntla, V.; Veluvolu, K.C.; Lee, M. Human implicit intent recognition based on the phase synchrony of EEG signals. Pattern Recognit. Lett. 2015, 66, 144–152. [Google Scholar] [CrossRef] [Scilit]
- Park, H.; Lee, A.; Lee, M.; Chang, M.S.; Kwak, H.W. Using eye movement data to infer human behavioral intentions. Comput. Hum. Behav. 2016, 63, 796–804. [Google Scholar] [CrossRef] [Scilit]
- Palaniappan, R. Brain Computer Interface Design Using Band Powers Extracted During Mental Tasks. In Proceedings of the 2nd International IEEE EMBS Conference on Neural Engineering, Pittsburgh, PA, USA, 16–19 March 2005. [Google Scholar]
- Wang, H.K.; Bi, L.Z.; Fei, W.J.; Wang, L. An EEG-Based Multi-Classification Method of Braking Intentions for Driver-Vehicle Interaction. In Proceedings of the 2019 IEEE International Conference on Real-Time Computing and Robotics (RCAR), Irkutsk, Russia, 4–9 August 2019; pp. 438–441. [Google Scholar]
- Nasa.Gov. MATB-II. Available online: https://matb.larc.nasa.gov/ (accessed on 1 February 2026).
- Liao, J.Q. Prediction and analysis methods of mental load. Ind. Eng. J. 1998, 1, 38–42. [Google Scholar]
- Liang, Y.Q.; Wang, W.; Qu, J.; Yang, J.; Liu, X.W. Human-Computer Interaction Behavior and Intention Prediction Model Based on Eye Movement Characteristics. Acta Electron. Sin. 2018, 46, 2993–3001. [Google Scholar]
- Slanzi, G.; Balazs, J.A.; Velasquez, J.D. Combining eye tracking, pupil dilation and EEG analysis for predicting web users click intention. Inf. Fusion 2017, 35, 51–57. [Google Scholar] [CrossRef] [Scilit]
- Wang, Y.; Gao, S.; Gao, X. Common Spatial Pattern Method for Channel Selelction in Motor Imagery Based Brain-computer Interface. In Proceedings of the 2005 IEEE Engineering in Medicine and Biology 27th Annual Conference, Shanghai, China, 1–4 September 2005. [Google Scholar]
- Chakraborty, B.; Ghosh, L.; Konar, A. Designing Phase-Sensitive Common Spatial Pattern Filter to Improve Brain-Computer Interfacing. IEEE Trans. Biomed. Eng. 2020, 67, 2064–2072. [Google Scholar] [CrossRef] [Scilit]
- Card, S.K. The Psychology of Human-Computer Interaction; CRC Press: Boca Raton, FL, USA, 1983. [Google Scholar]
- Taylor, M.M. Editorial: Perceptual Control Theory and its application. Int. J. Hum. Comput. Stud. 1999, 50, 433–444. [Google Scholar] [CrossRef] [Scilit]
- Gaulke, W.; Ziegler, J. Rule-enhanced task models for increased expressiveness and compactness. In Proceedings of the 8th ACM SIGCHI Symposium on Engineering Interactive Computing Systems, Brussels, Belgium, 21–24 June 2016; Association for Computing Machinery: New York, NY, USA, 2016; pp. 4–15. [Google Scholar]
- Clerckx, T.; Luyten, K.; Coninx, K. DynaMo-AID: A Design Process and a Runtime Architecture for Dynamic Model-Based User Interface Development. In Proceedings of the IFIP International Conference on Engineering for Human-Computer Interaction, Hamburg, Germany, 11–13 July 2004; Springer: Berlin/Heidelberg, Germany, 2004; pp. 77–95. [Google Scholar]
- Klug, T.; Kangasharju, J. Executable task models. In Proceedings of the 4th International Workshop on Task Models and Diagrams, Gdansk, Poland, 26–27 September 2005; Association for Computing Machinery: New York, NY, USA, 2005; pp. 119–122. [Google Scholar]
- He, G.; Dang, Y.; Zhou, L.; Dai, Y.; Que, Y.; Ji, X. Architecture model proposal of innovative intelligent manufacturing in the chemical industry based on multi-scale integration and key technologies. Comput. Chem. Eng. 2020, 141, 106967. [Google Scholar] [CrossRef] [Scilit]
- Hu, B.; Zhong, R.; Feng, Y.; Yang, C.; Wang, T. Digital shop floor manufacturing capability modeling and adaptive scheduling in human-cyber-physical interconnected environment. J. Mech. Eng. 2025, 61, 23–39. [Google Scholar]
- Jolliffe, I.; Cadima, J. Principal component analysis: A review and recent developments. Philos. Trans. R. Soc. A Math. Phys. Eng. Sci. 2016, 374, 20150202. [Google Scholar] [CrossRef] [Scilit]
- Lachaux, J.P.; Rodriguez, E.; Martinerie, J.; Varela, F.J. Measuring phase synchrony in brain signals. Hum. Brain Mapp. 1999, 8, 194–208. [Google Scholar] [CrossRef] [Scilit]
- Oostenveld, R.; Fries, P.; Maris, E.; Schoffelen, J.-M. FieldTrip: Open source software for advanced analysis of MEG, EEG, and invasive electrophysiological data. Comput. Intell. Neurosci. 2011, 2011, 156869. [Google Scholar] [CrossRef] [Scilit]
- Van Veen, B.; Van Drongelen, W.; Yuchtman, M.; Suzuki, A. Localization of brain electrical activity via linearly constrained minimum variance spatial filtering. IEEE Trans. Biomed. Eng. 1997, 44, 867–880. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Tzoutio-Mazoyera, N.; Landeau, B.; Papathanassiou, D.; Crivello, F.; Etard, O.; Delcroix, N.; Tzourio-Mazoyer, B.; Joliot, M. Automated anatomical labeling of activations in SPM using a macroscopic anatomical parcellation of the MNI MRI single-subject brain. NeuroImage 2002, 15, 273–289. [Google Scholar] [CrossRef] [Scilit] [PubMed]
- Zalesky, A.; Fornito, A.; Bullmore, E.T. Network-based statistic: Identifying differences in brain networks. NeuroImage 2010, 53, 1197–1207. [Google Scholar] [CrossRef] [Scilit] [PubMed]
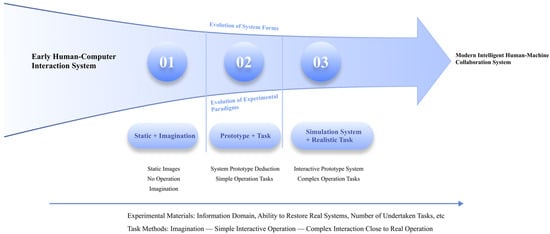
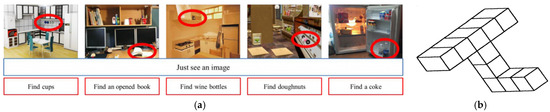
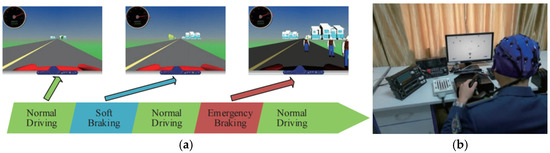
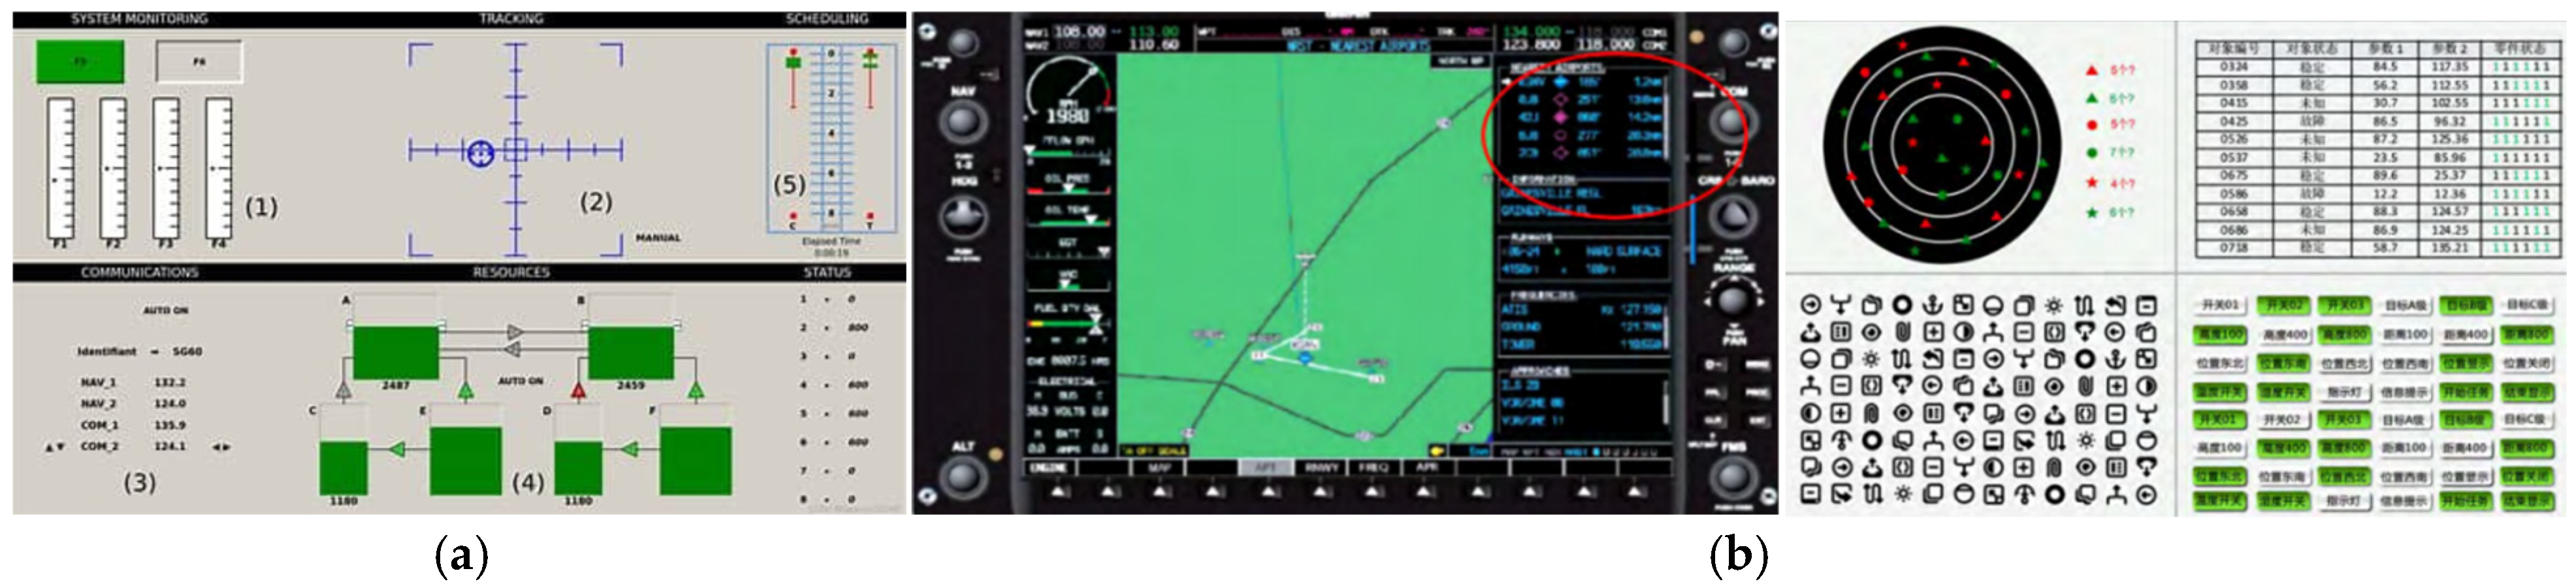
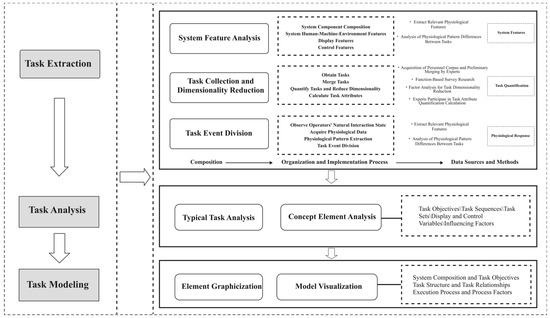
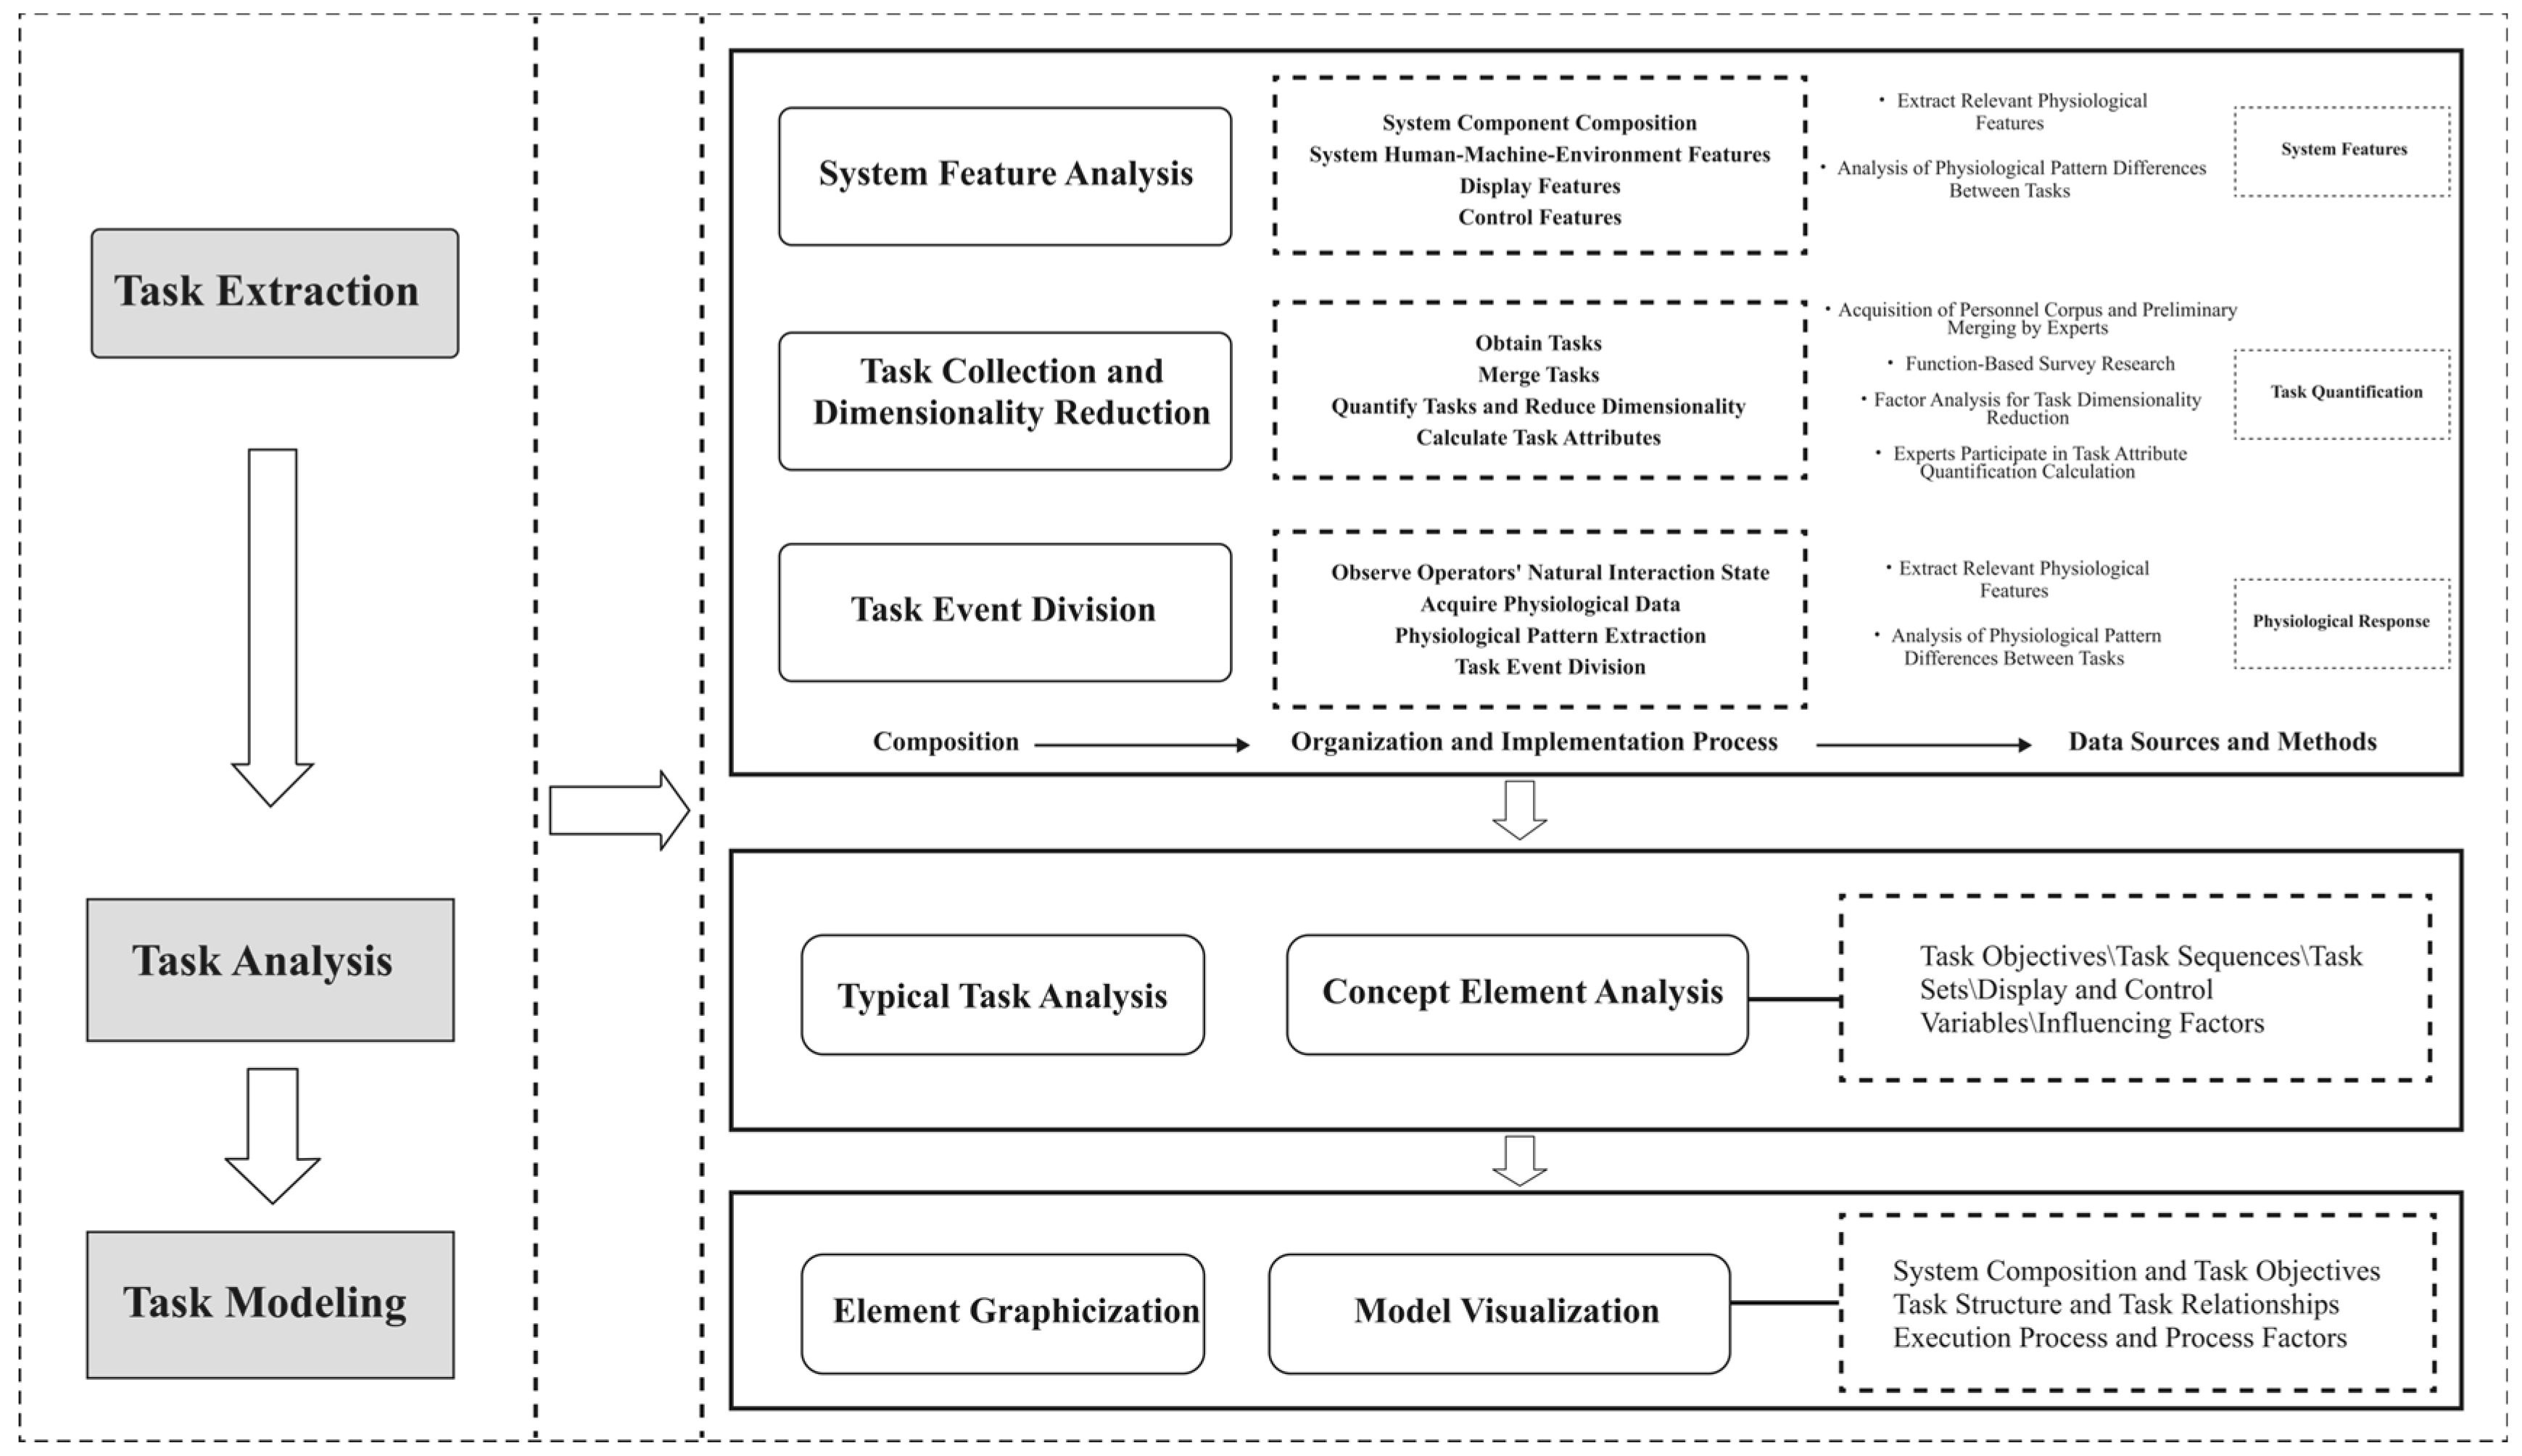
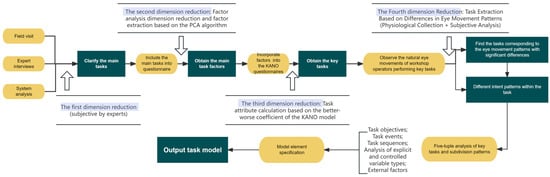
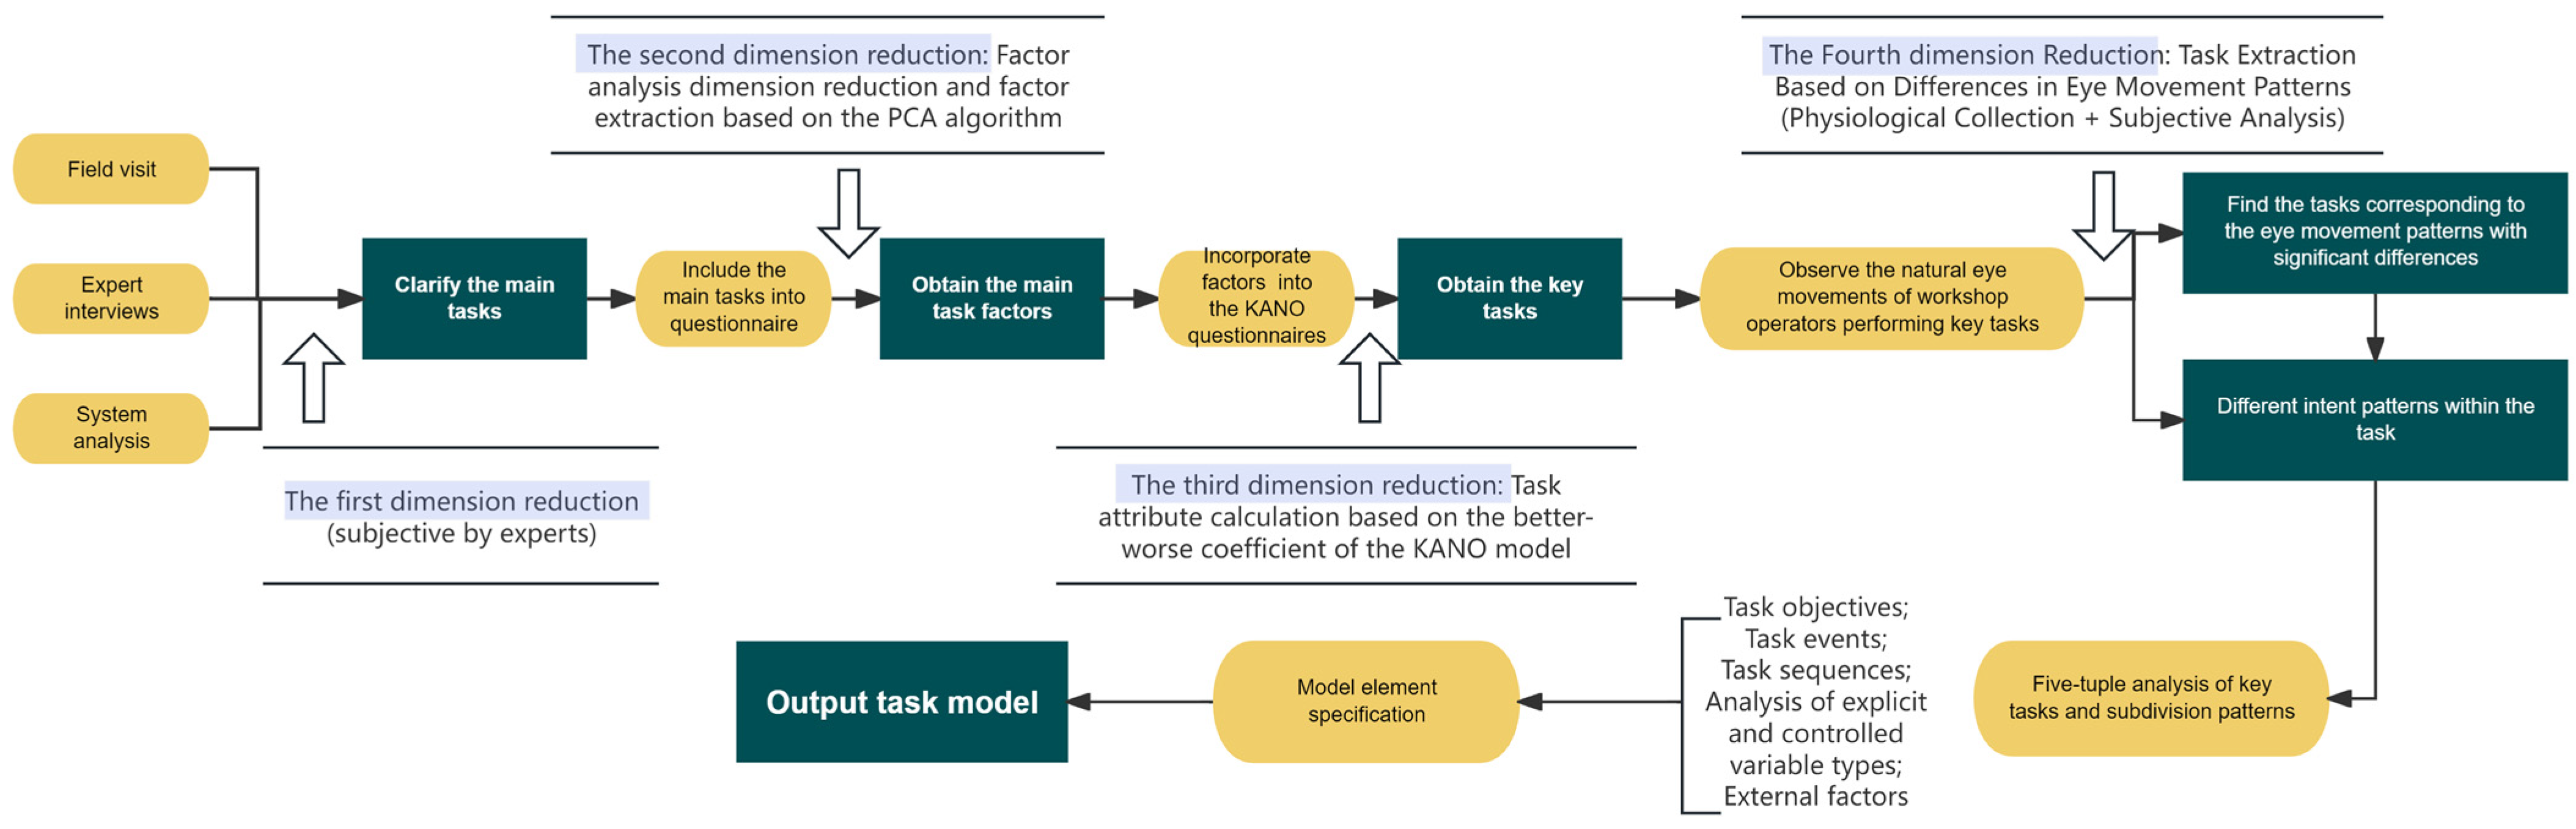
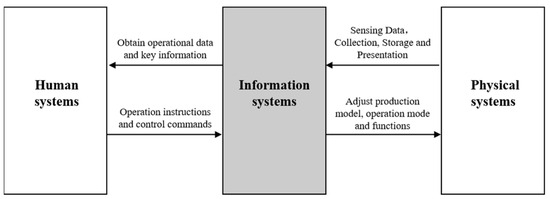
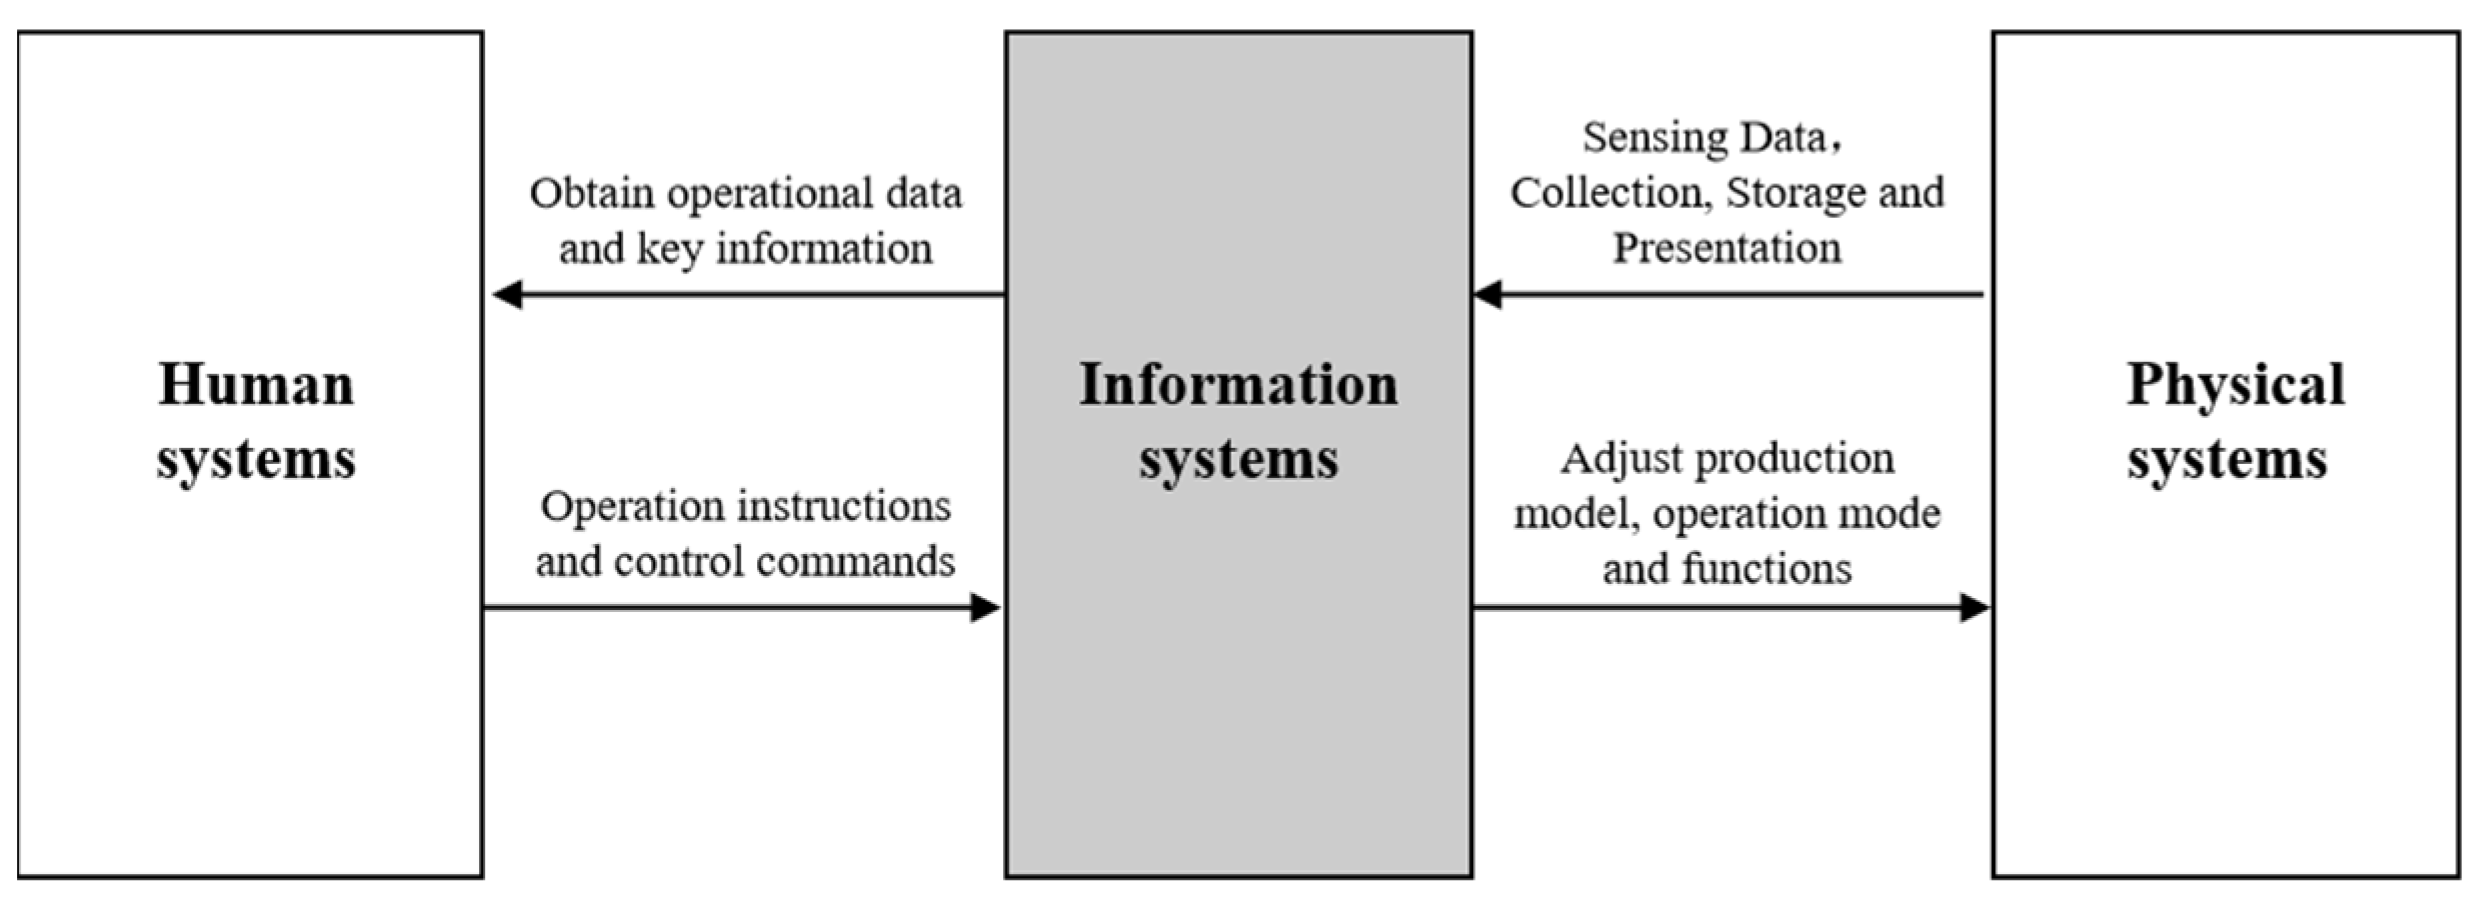
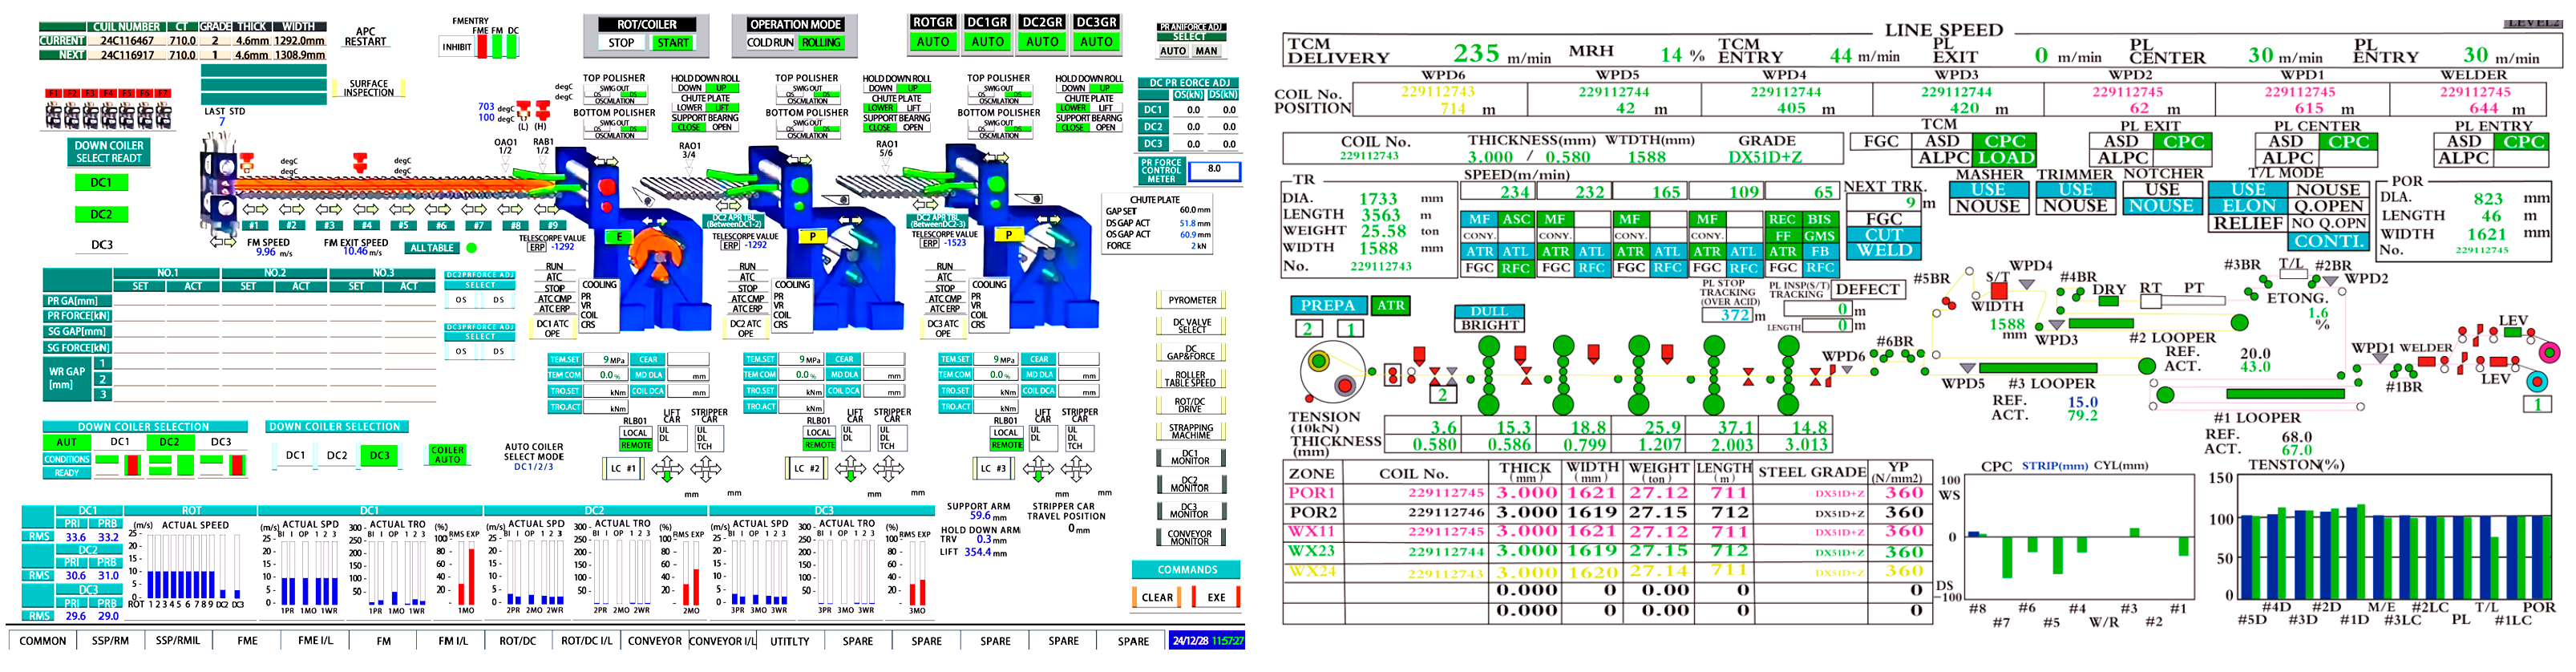
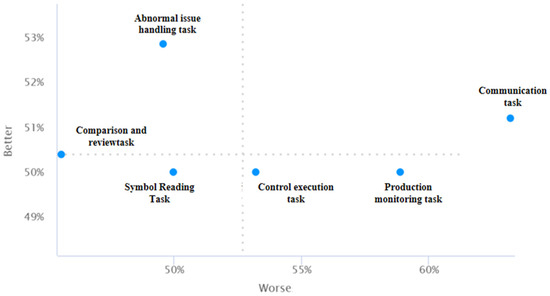
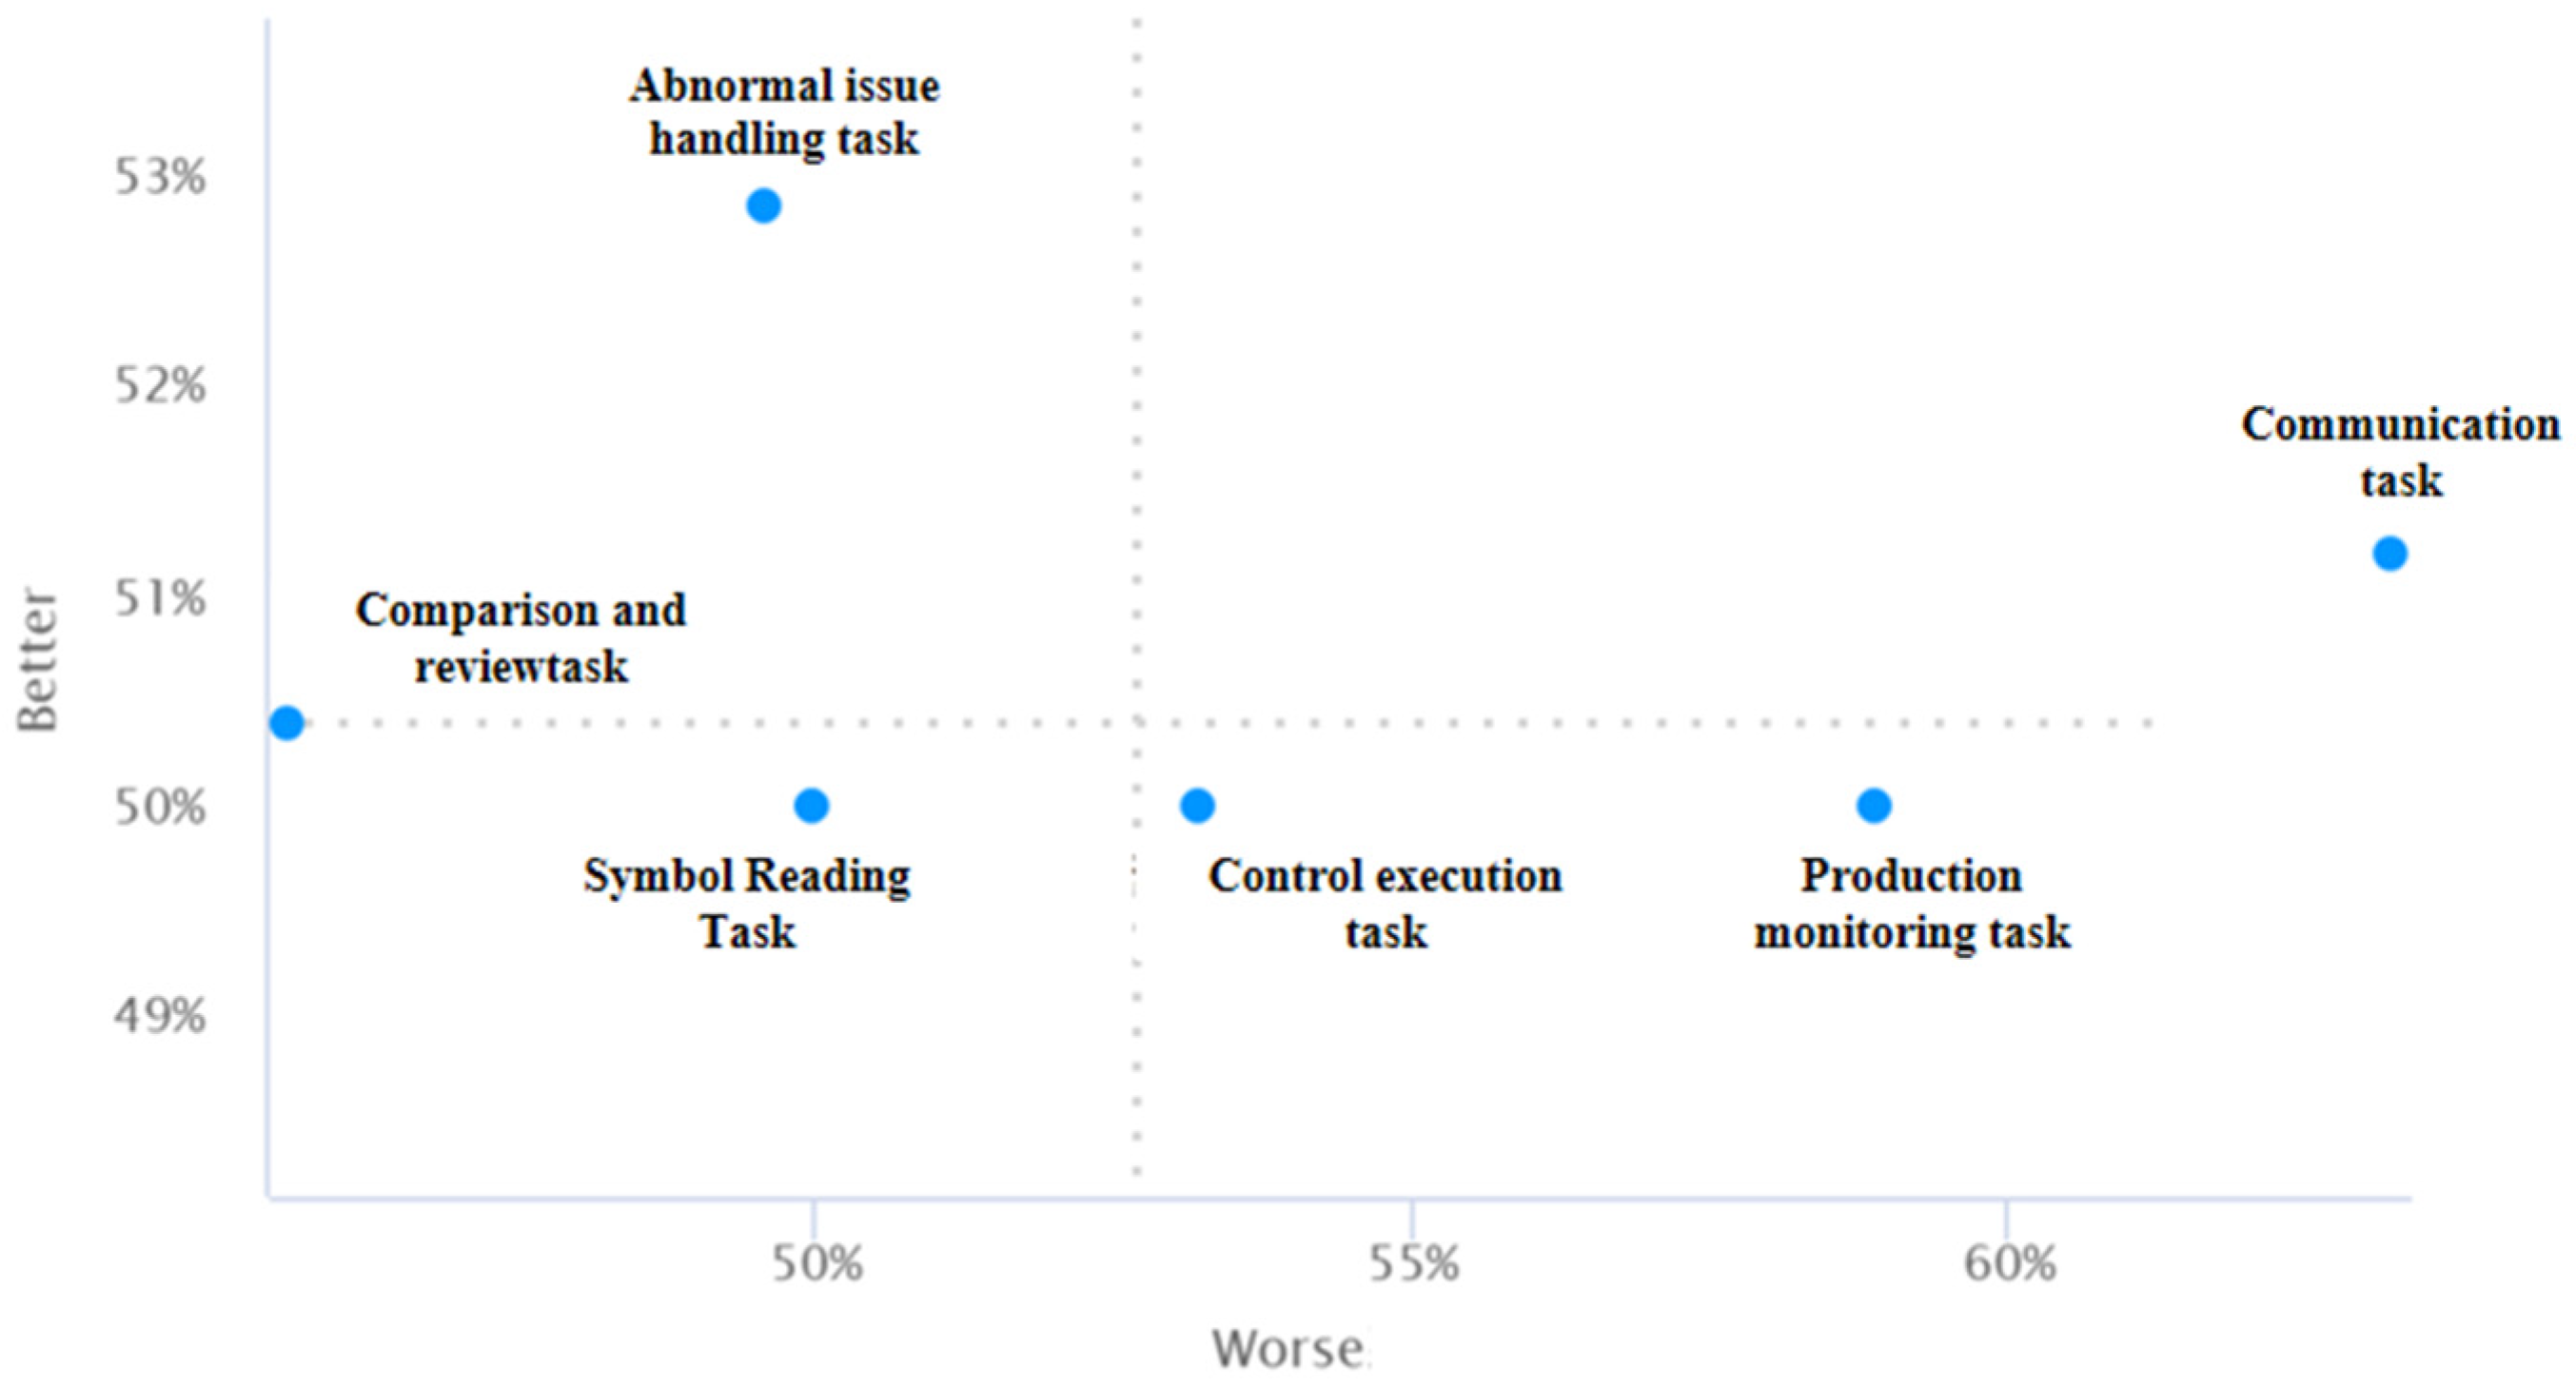
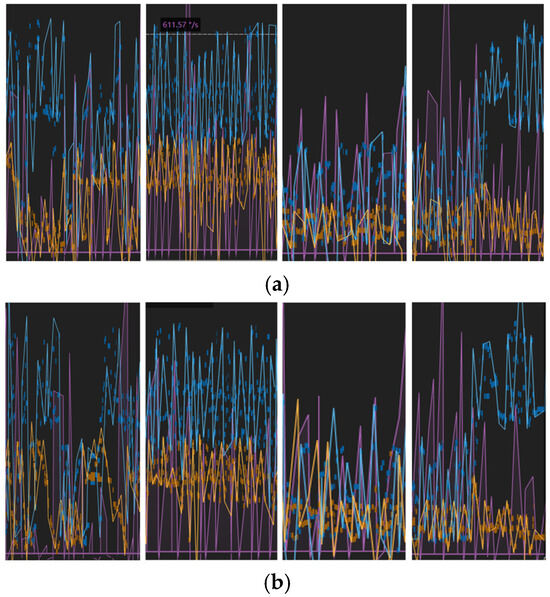
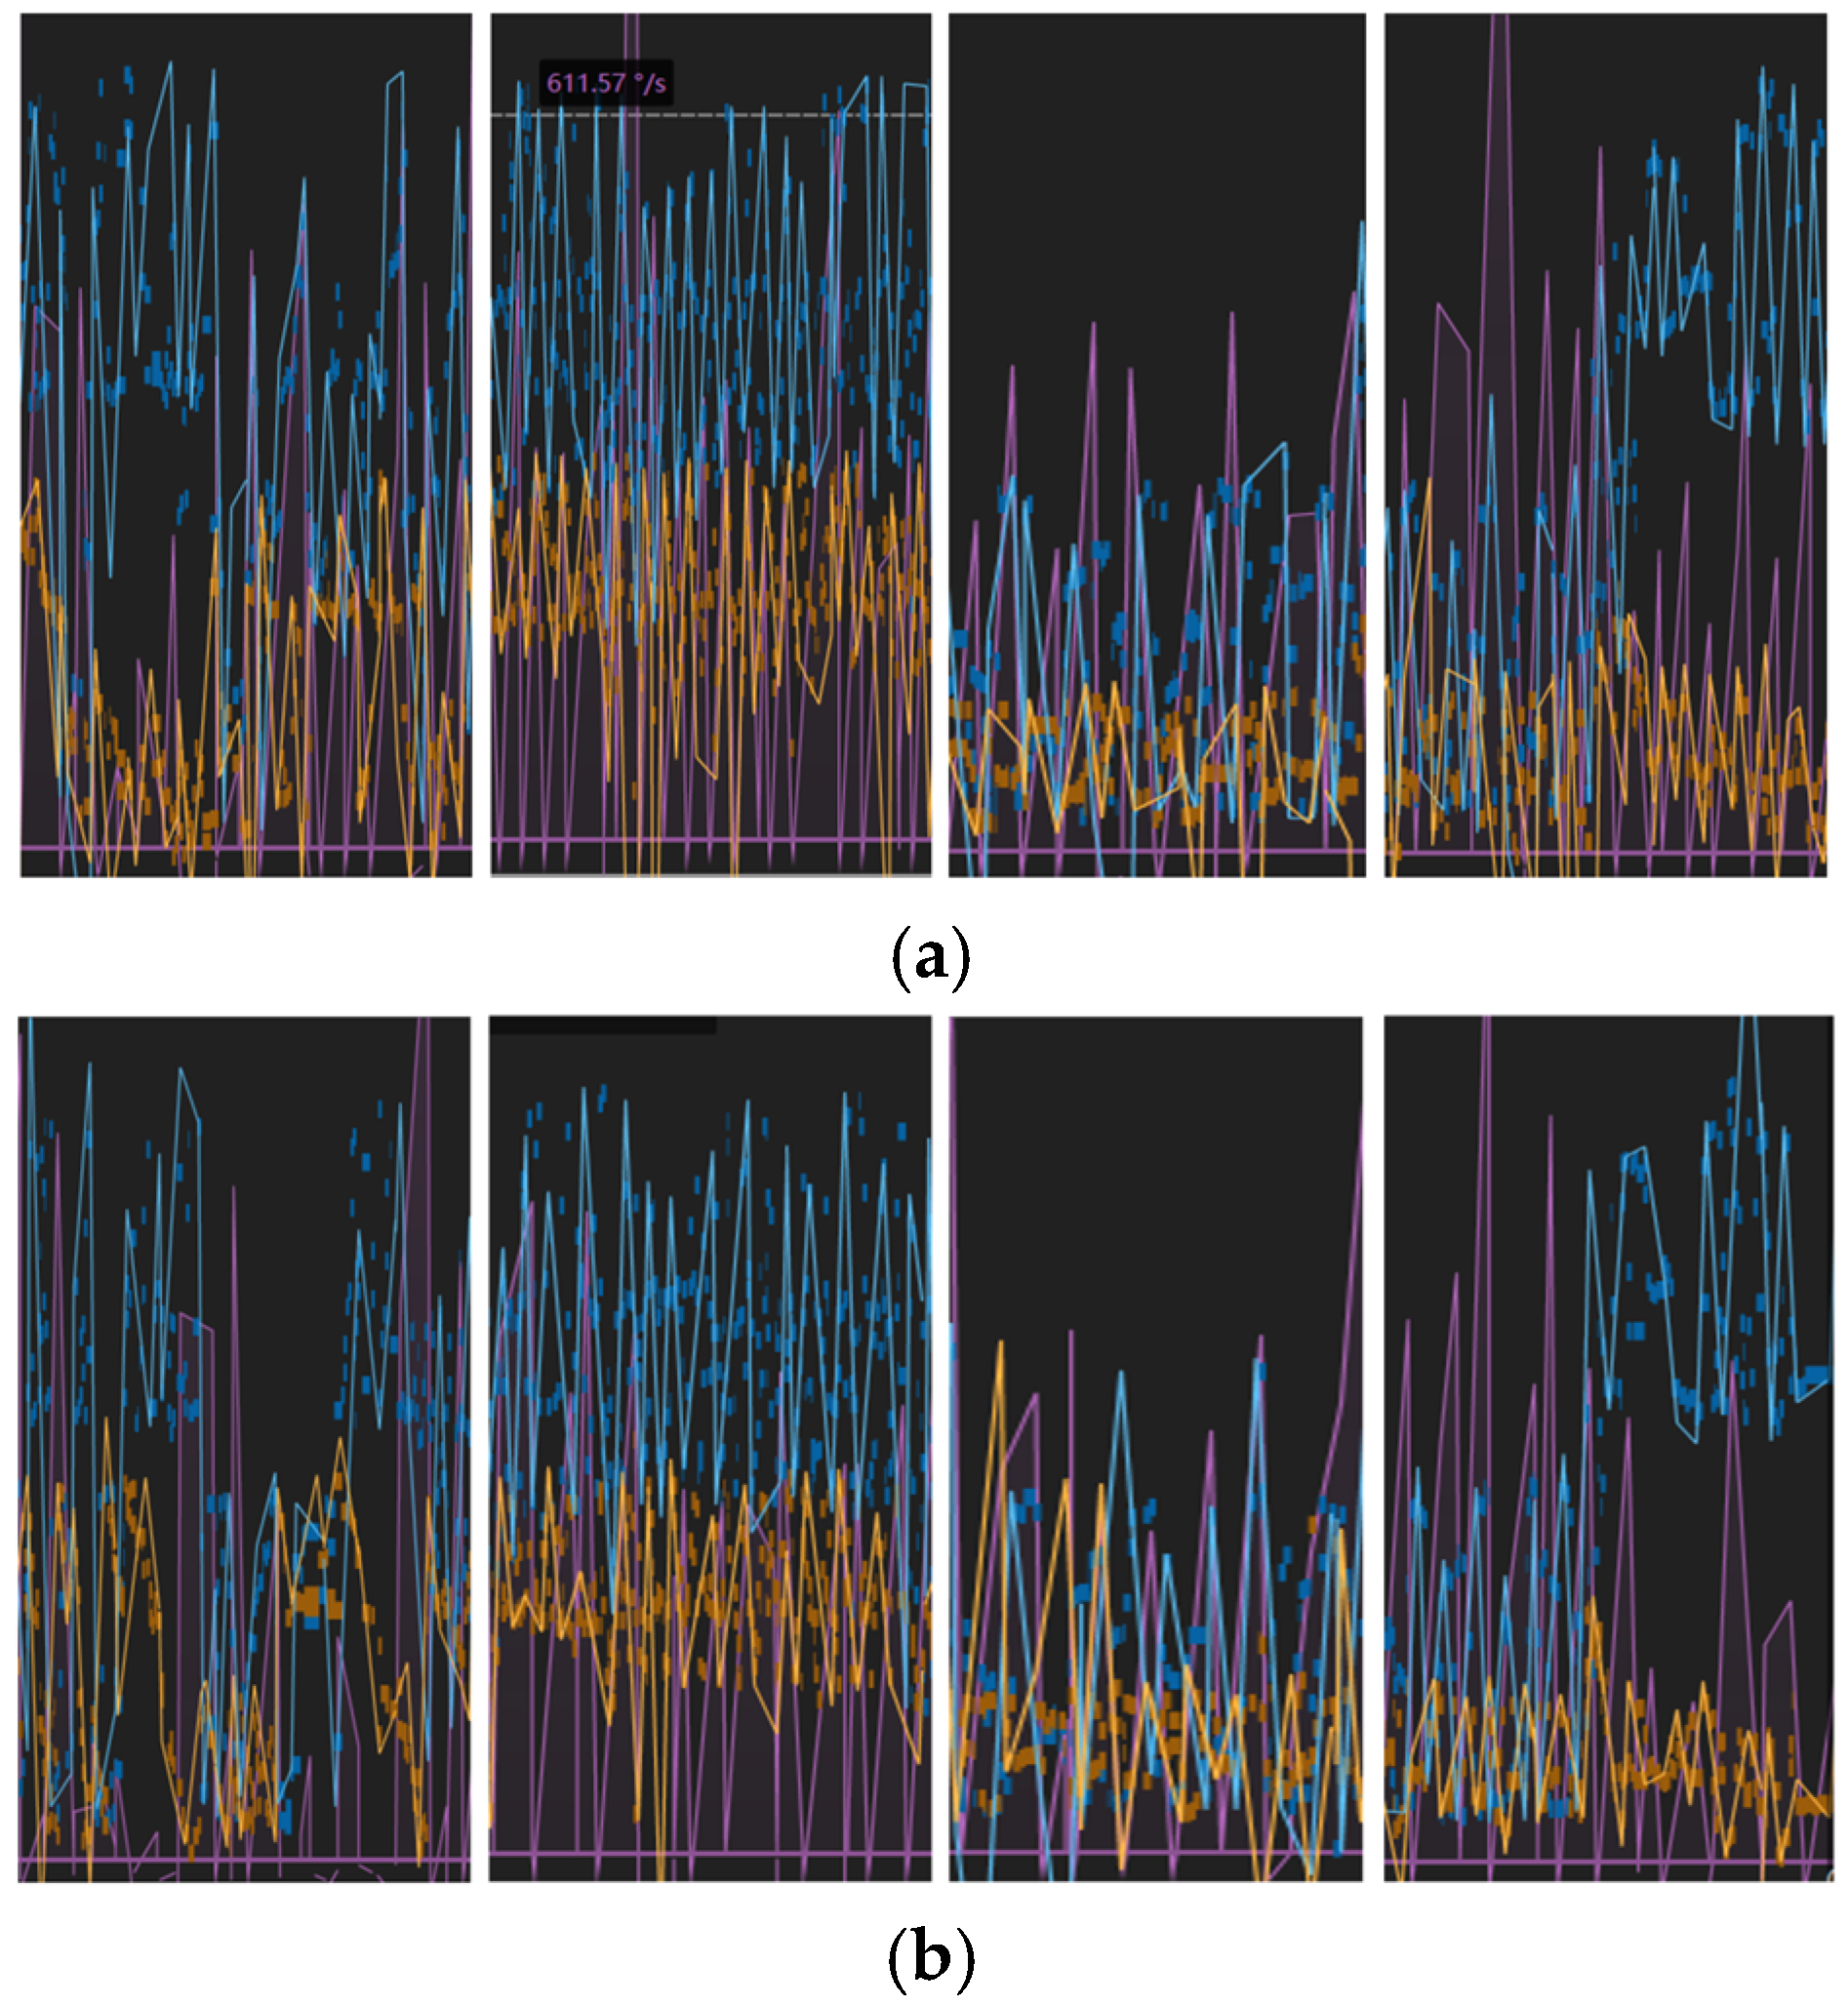
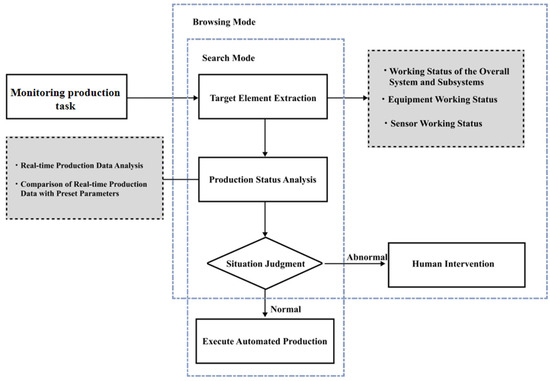
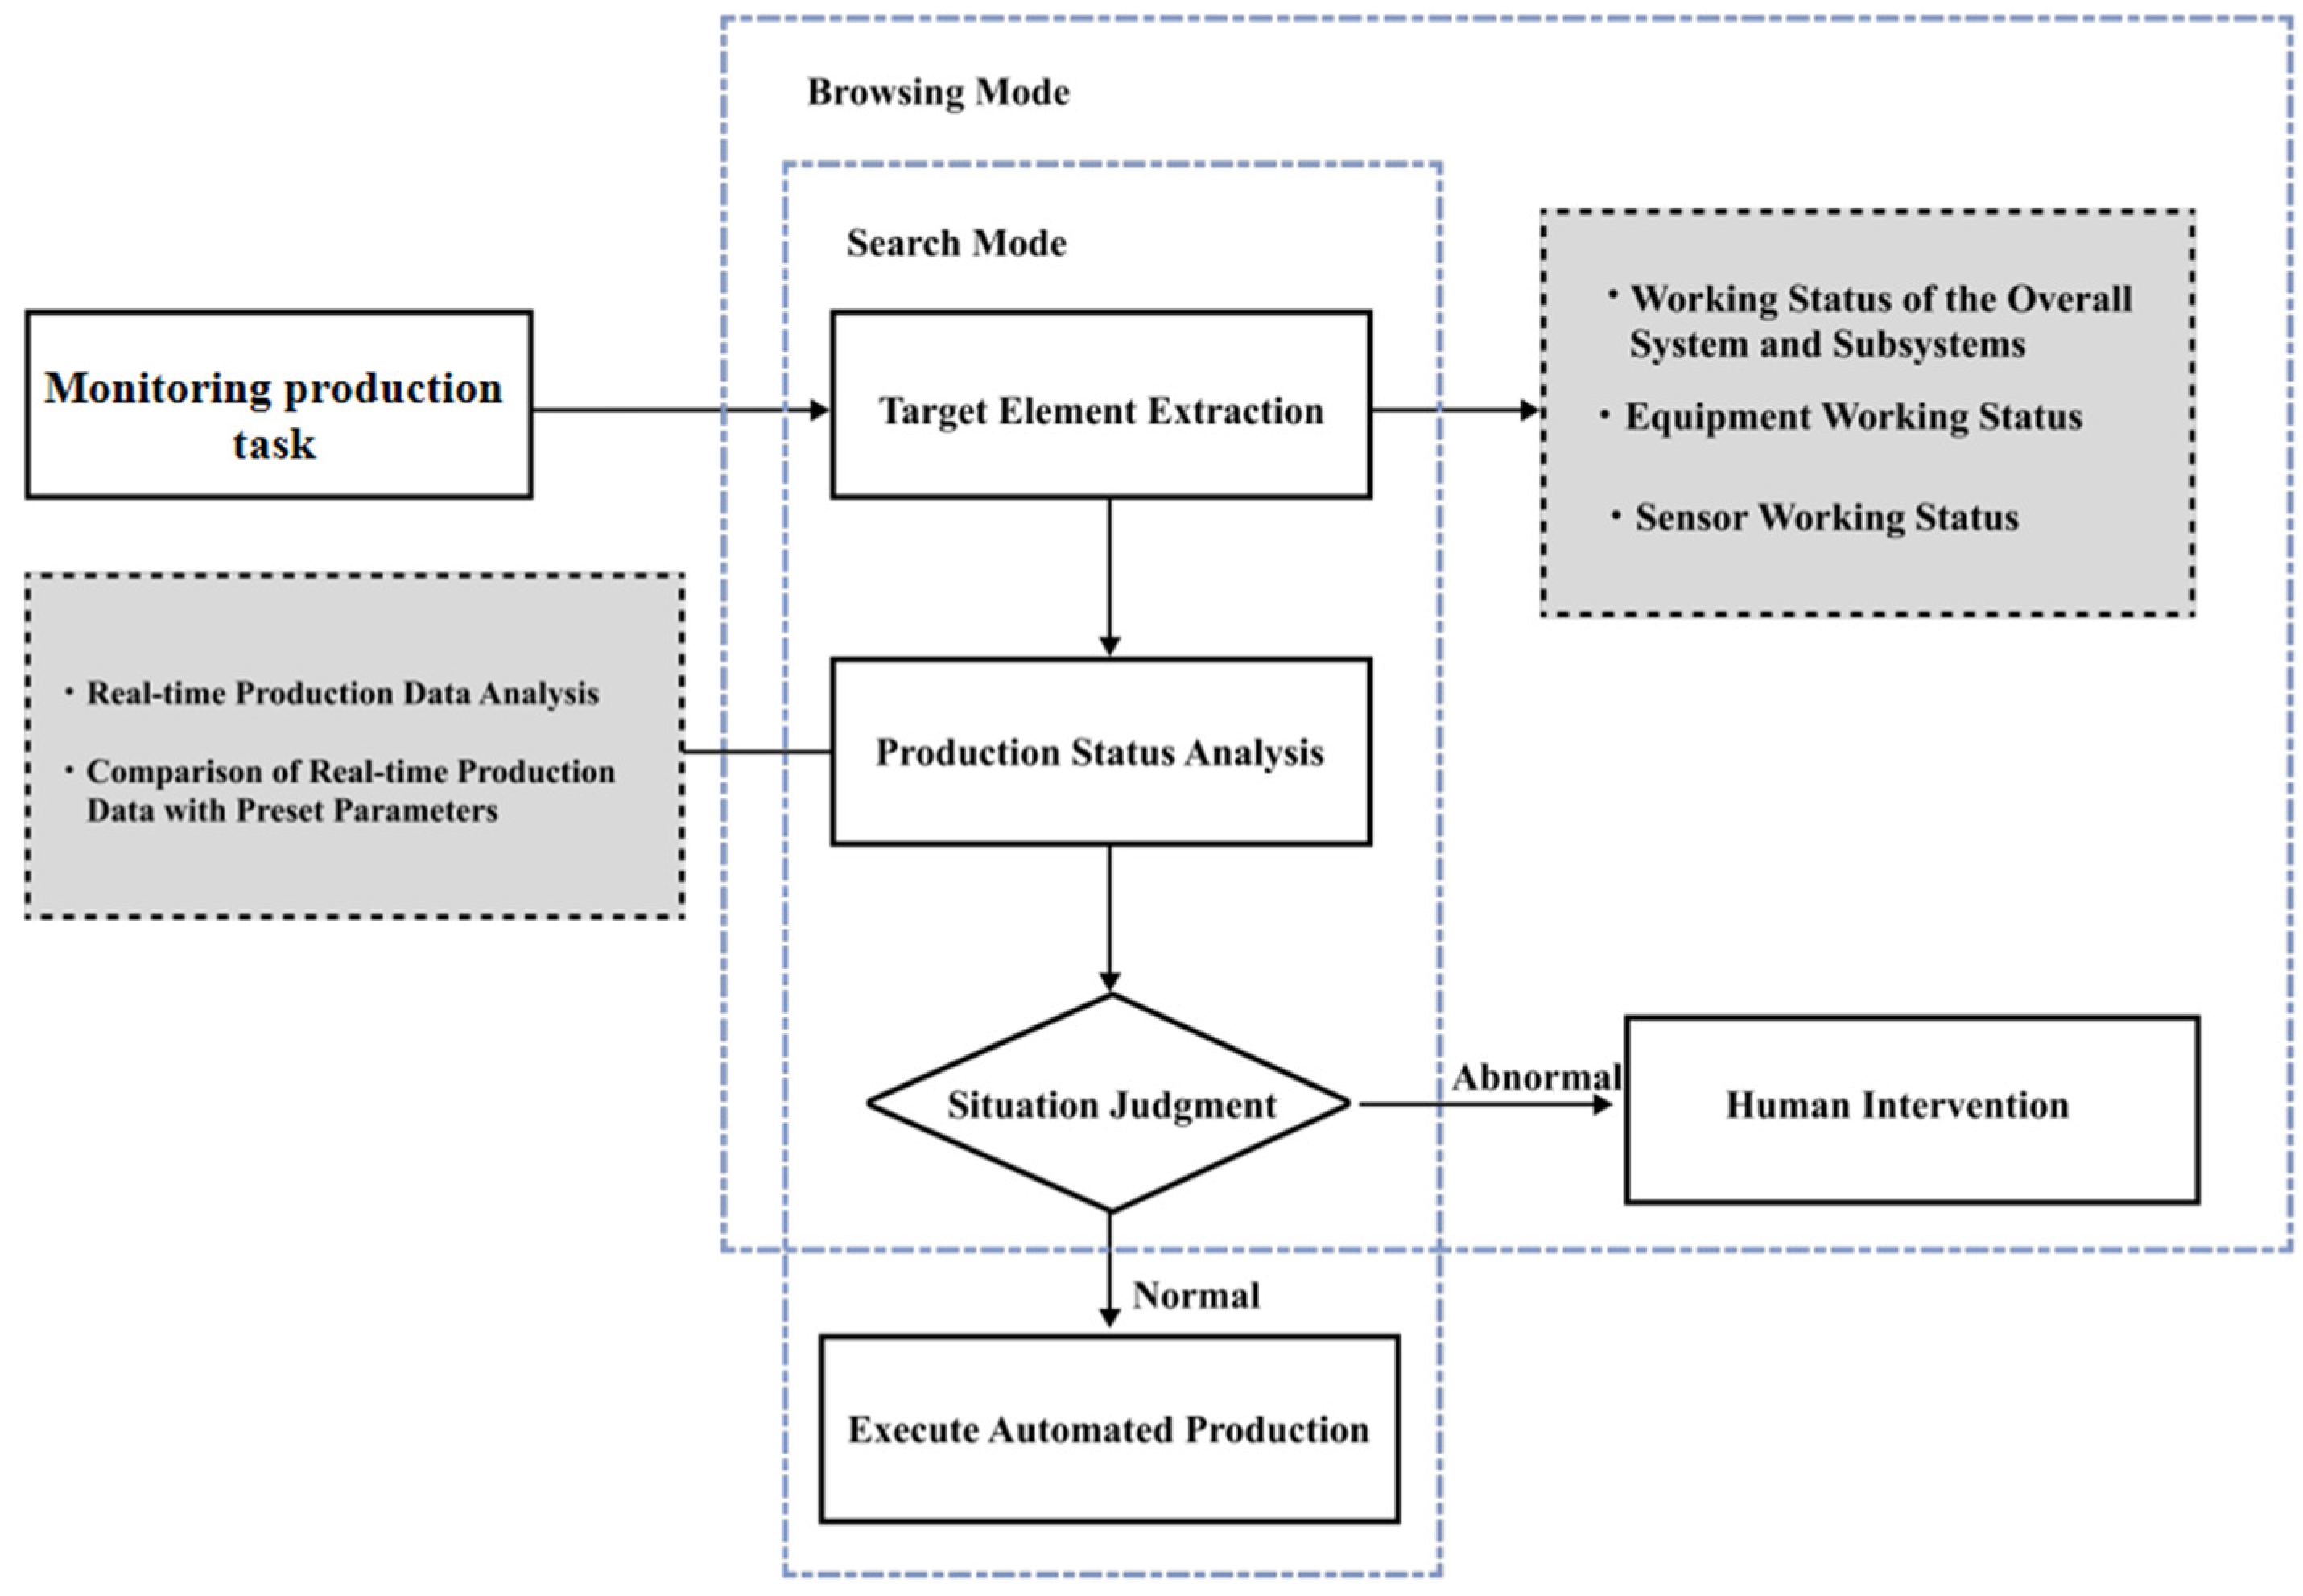
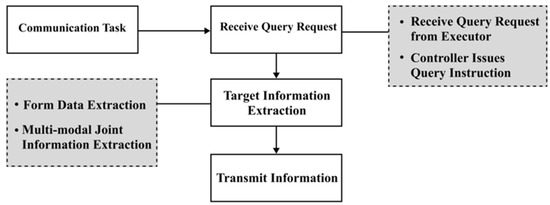
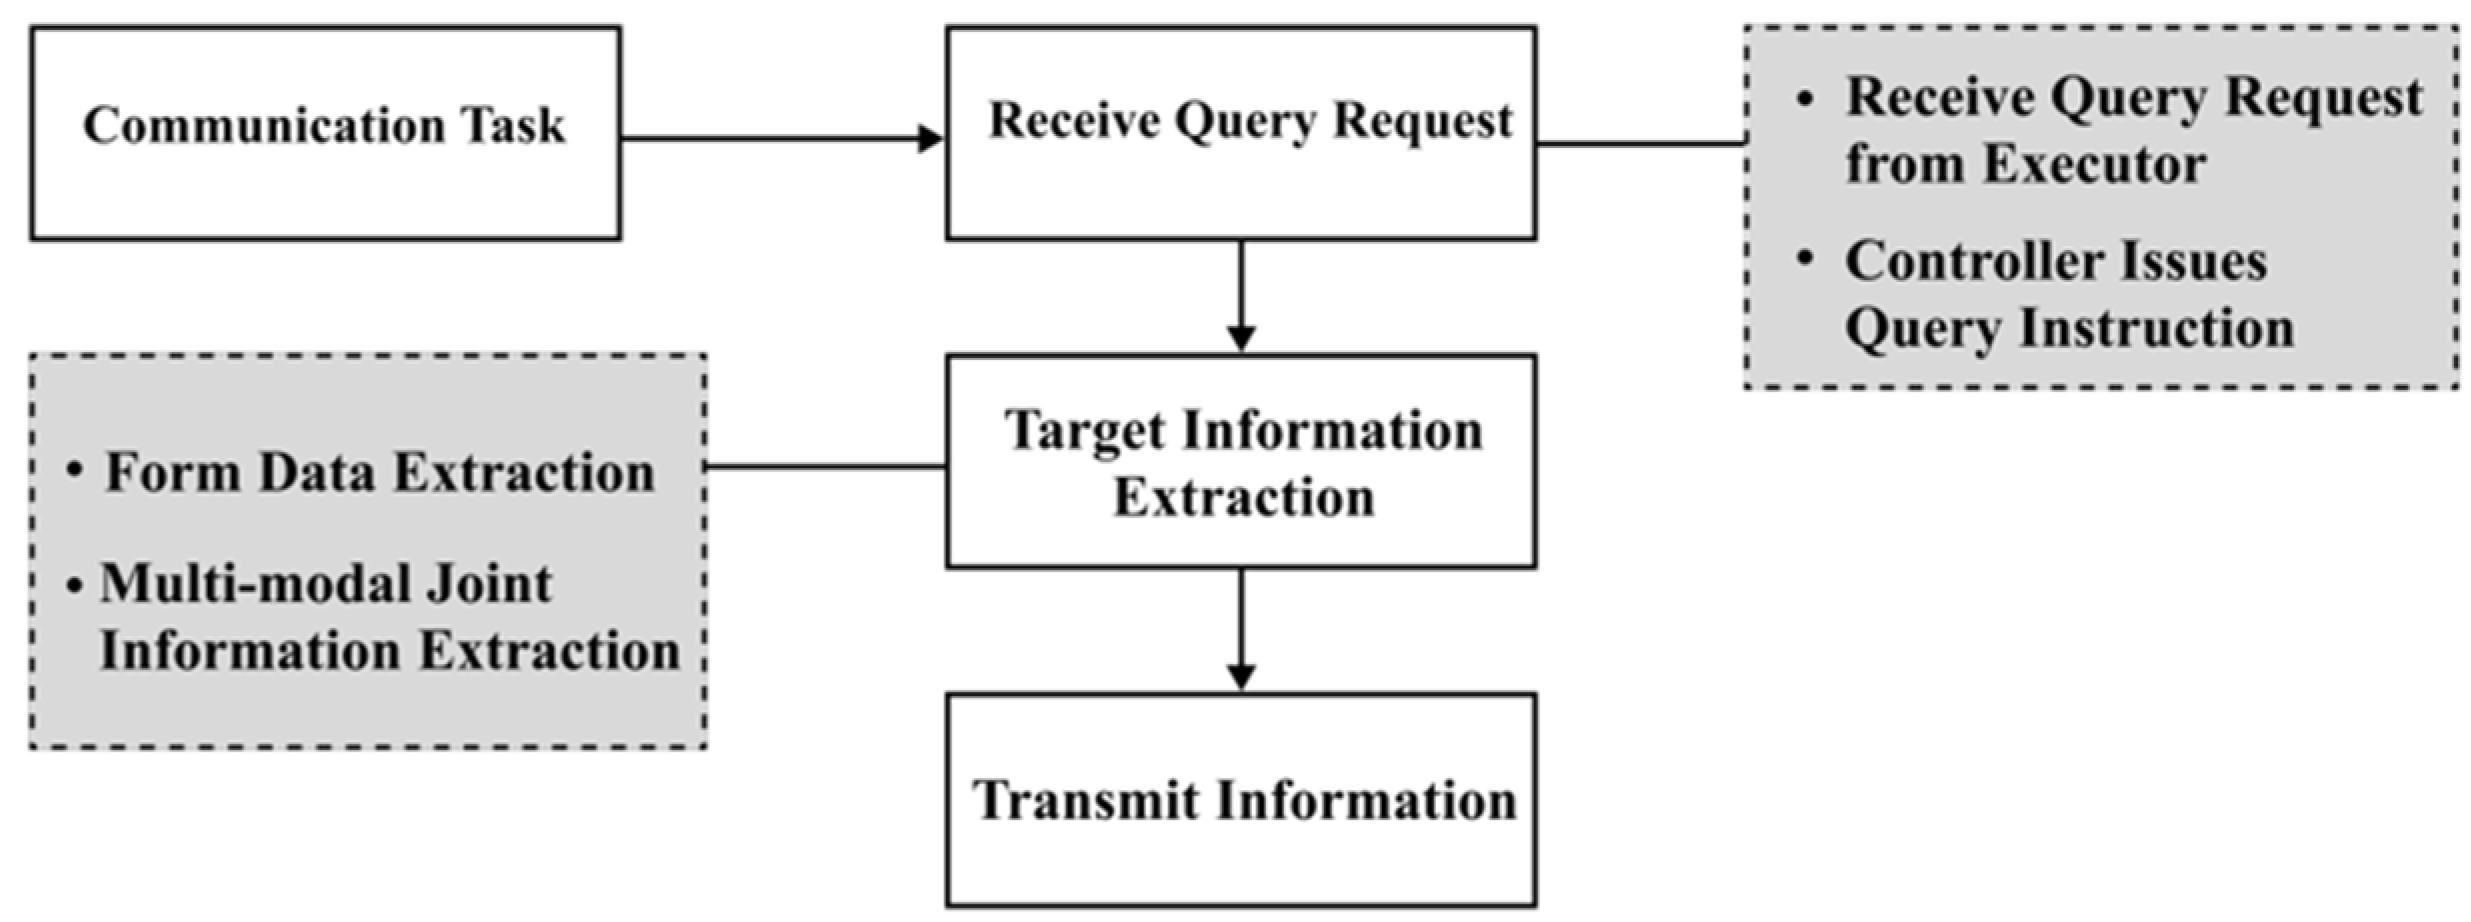
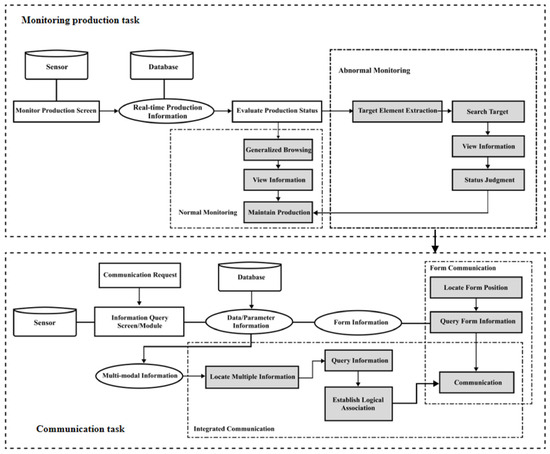
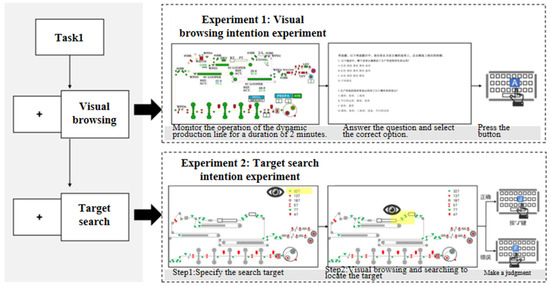
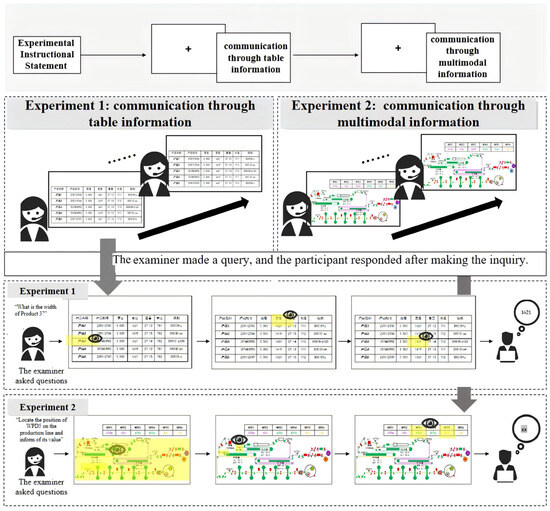
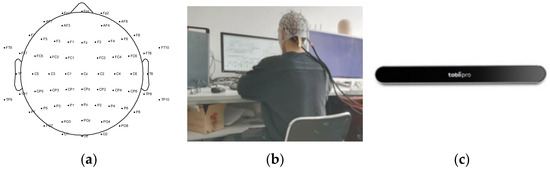
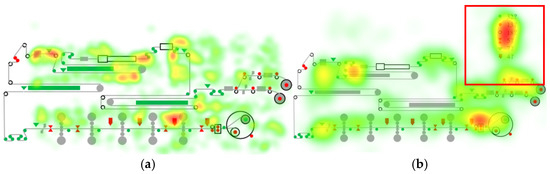
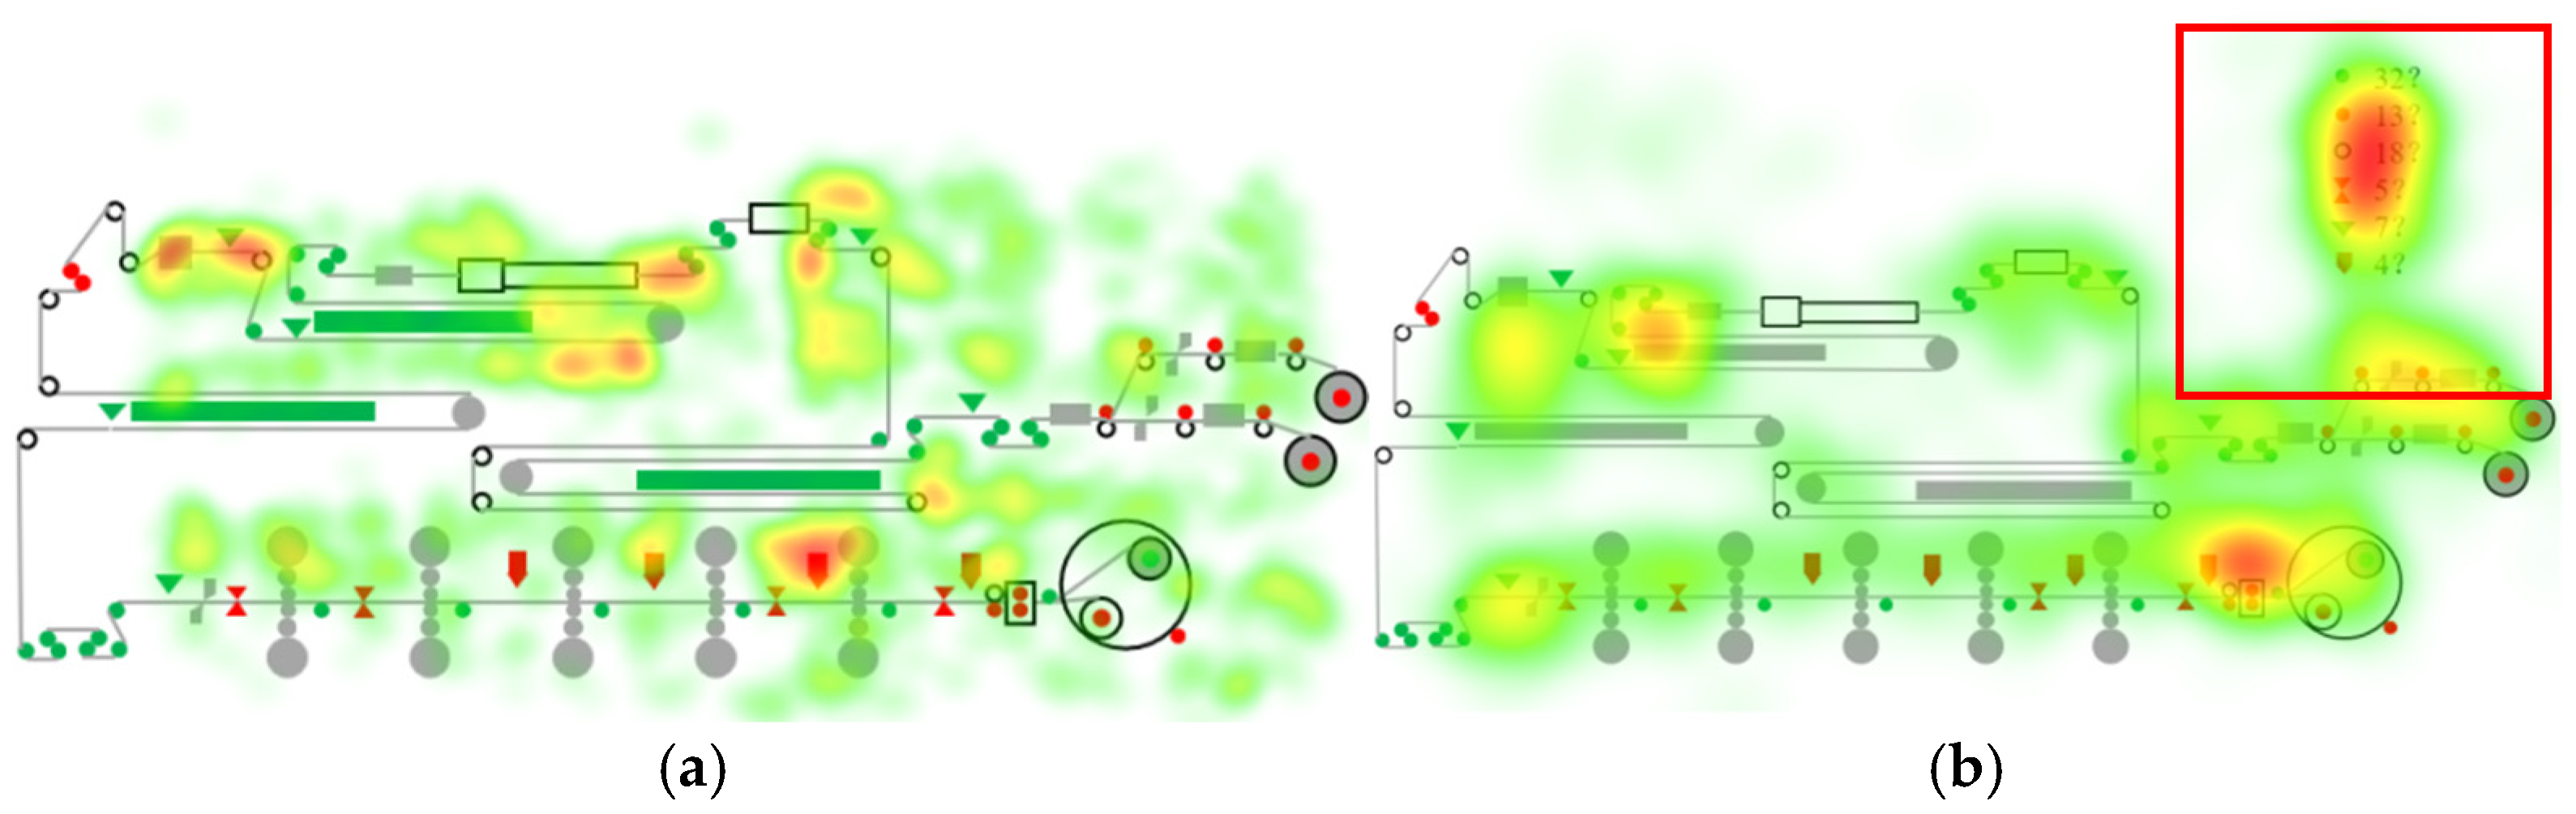
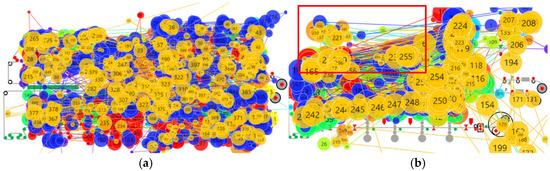
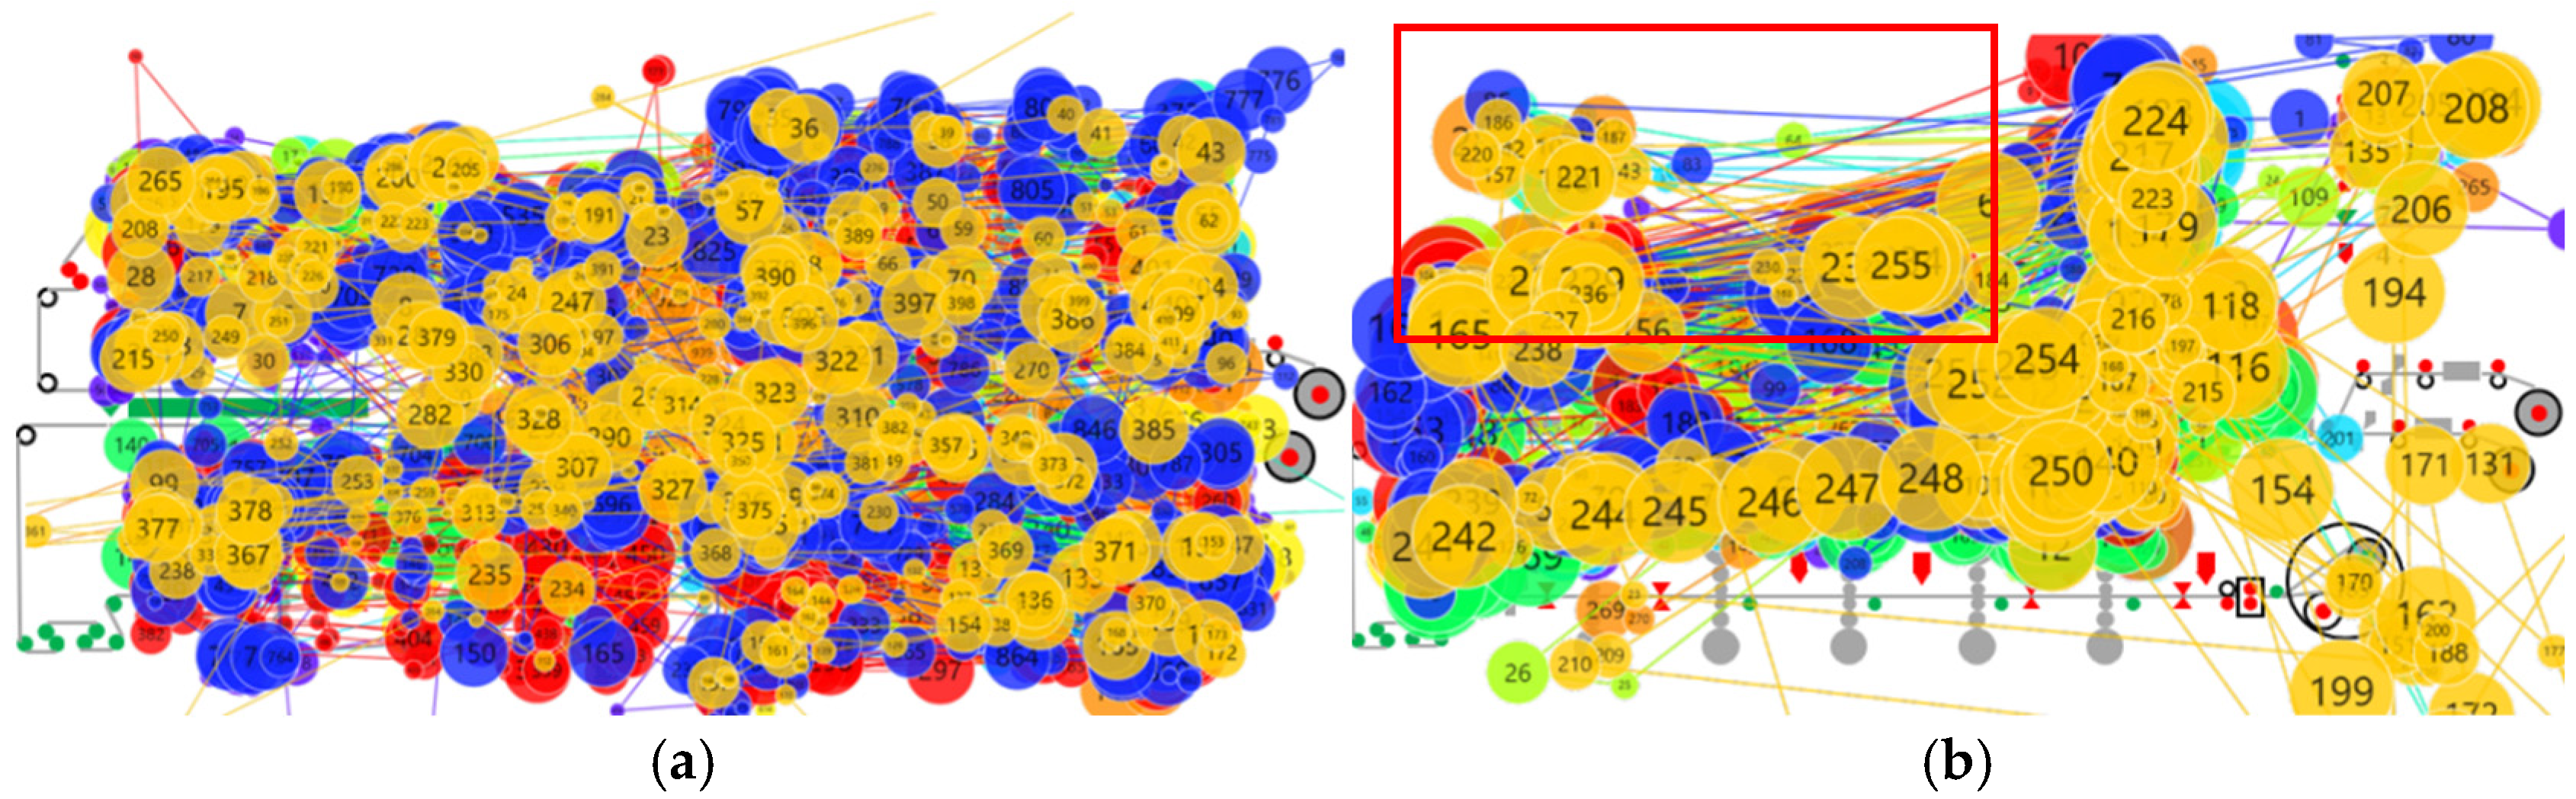
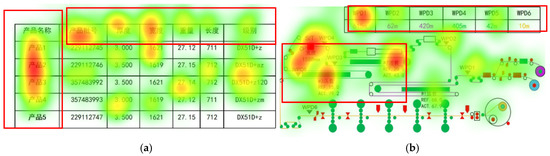
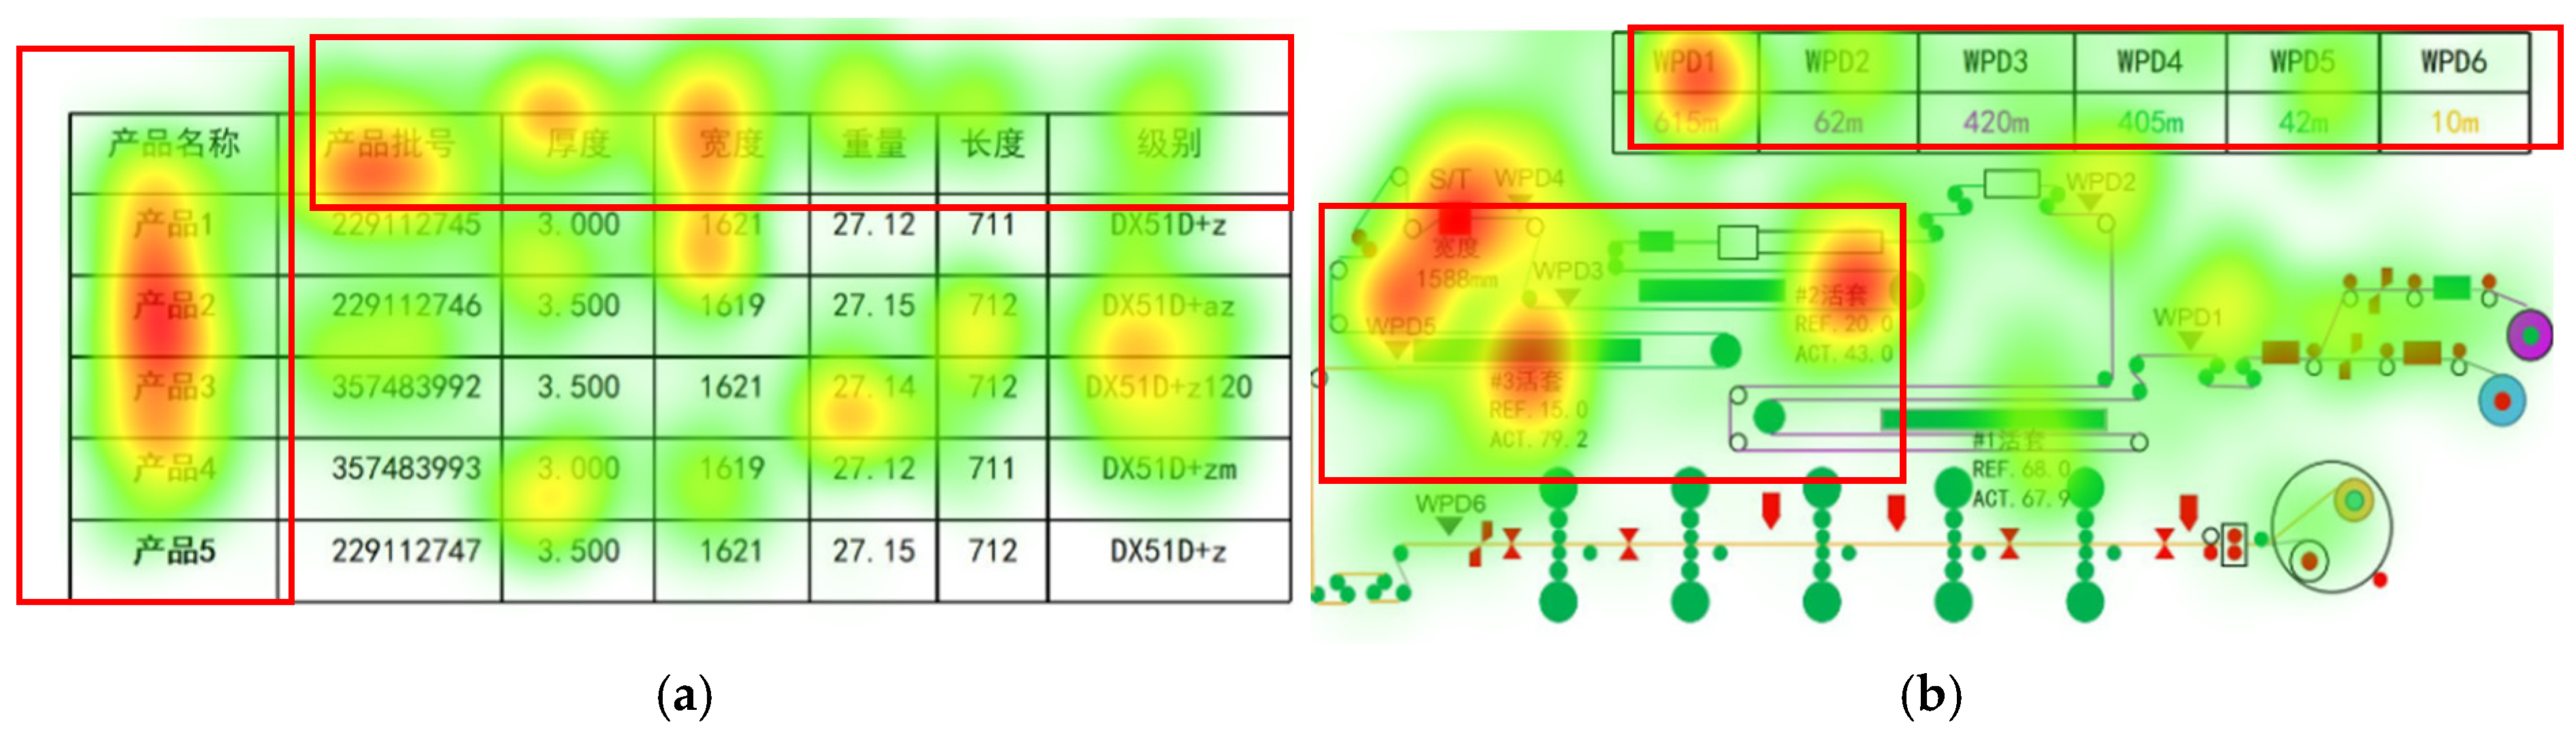
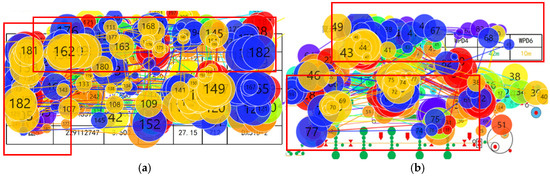
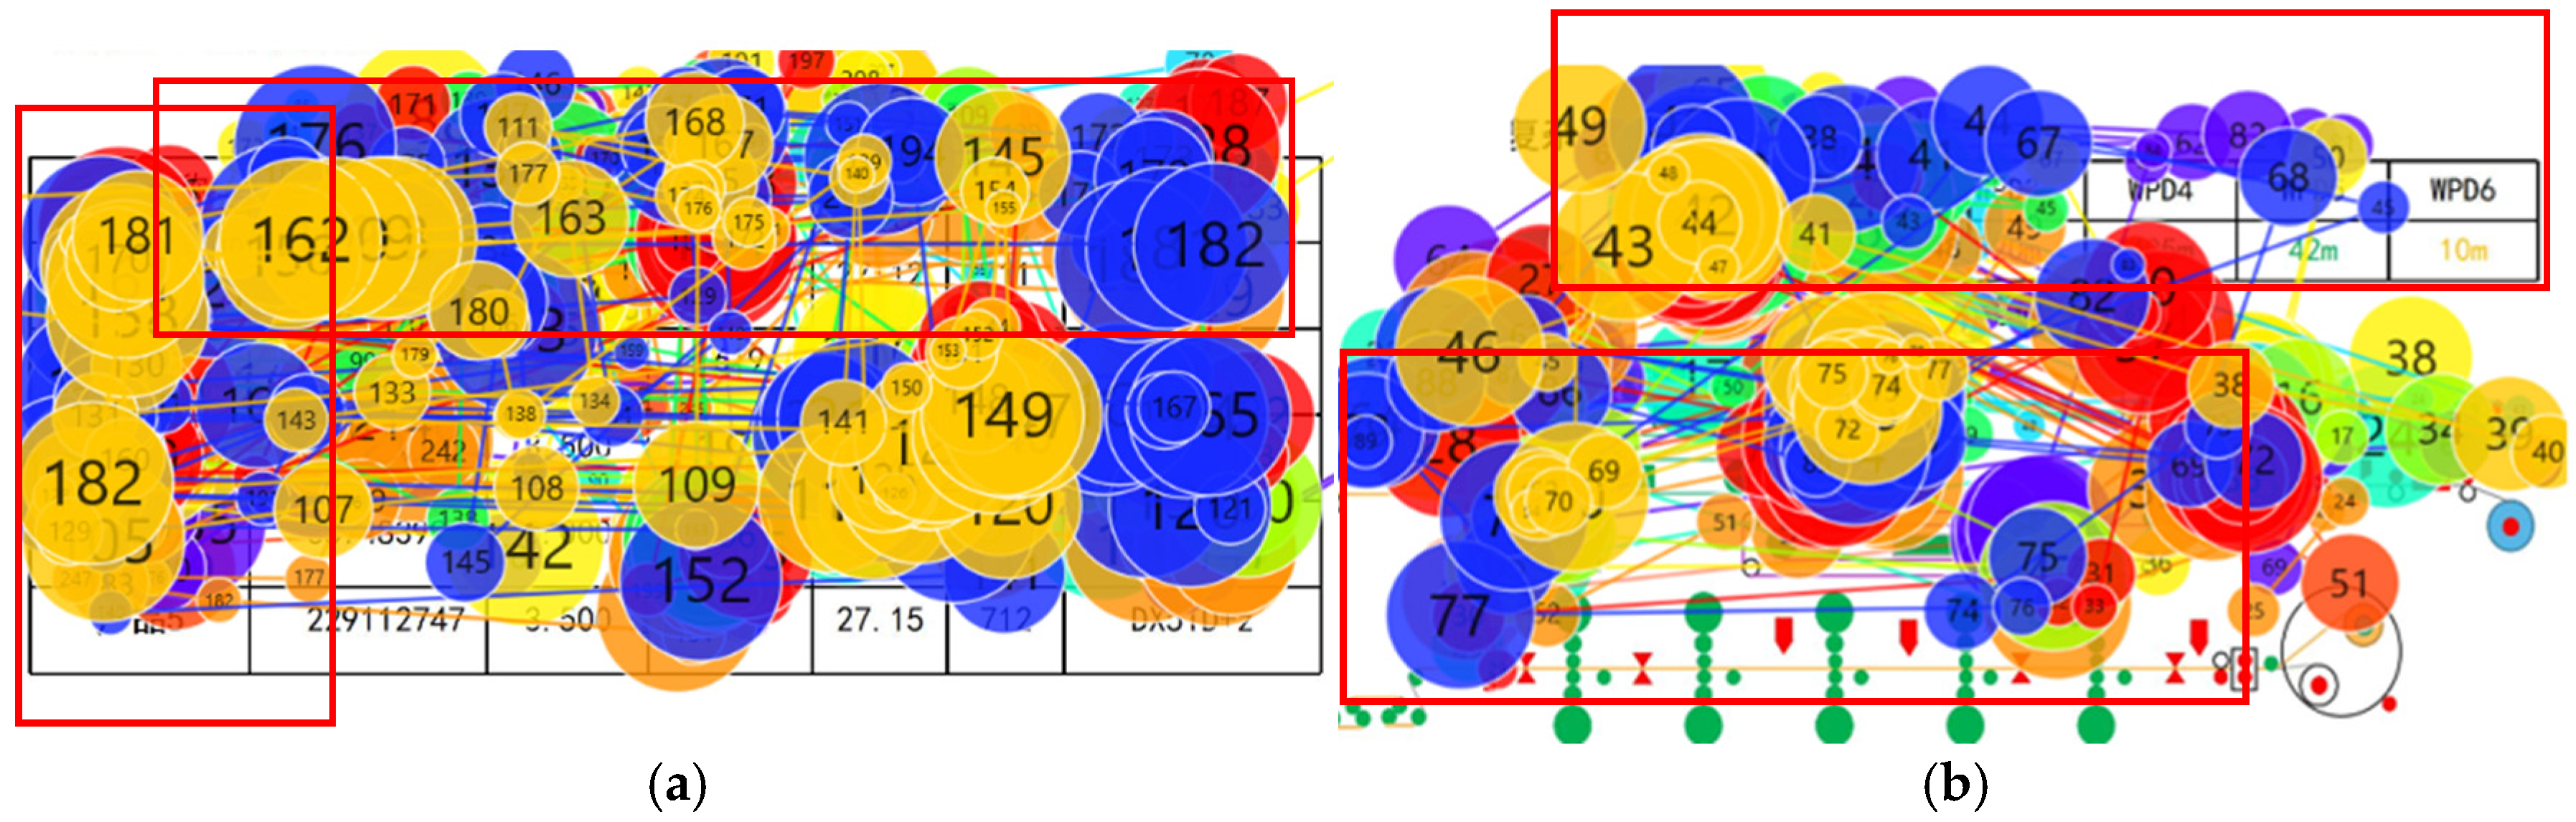
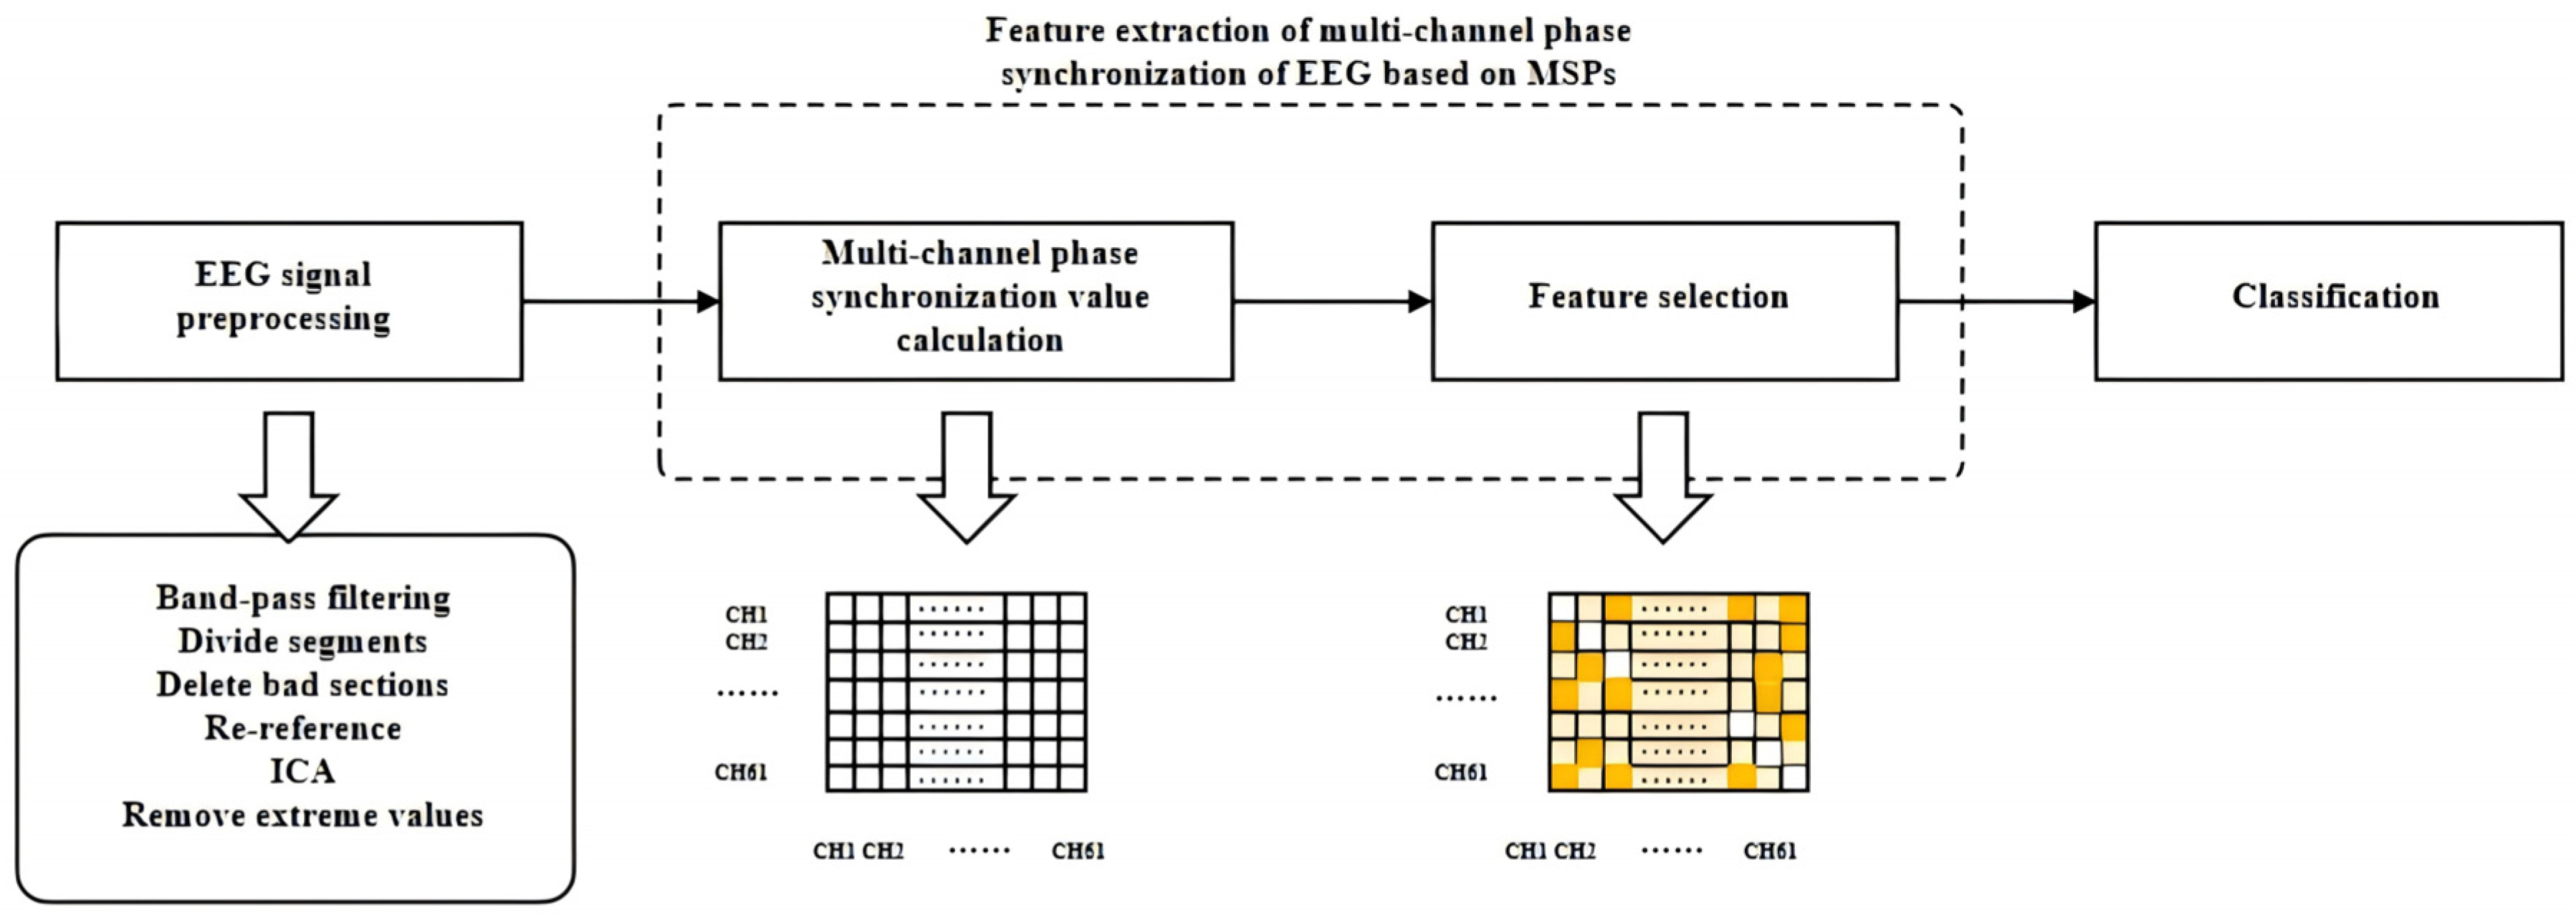
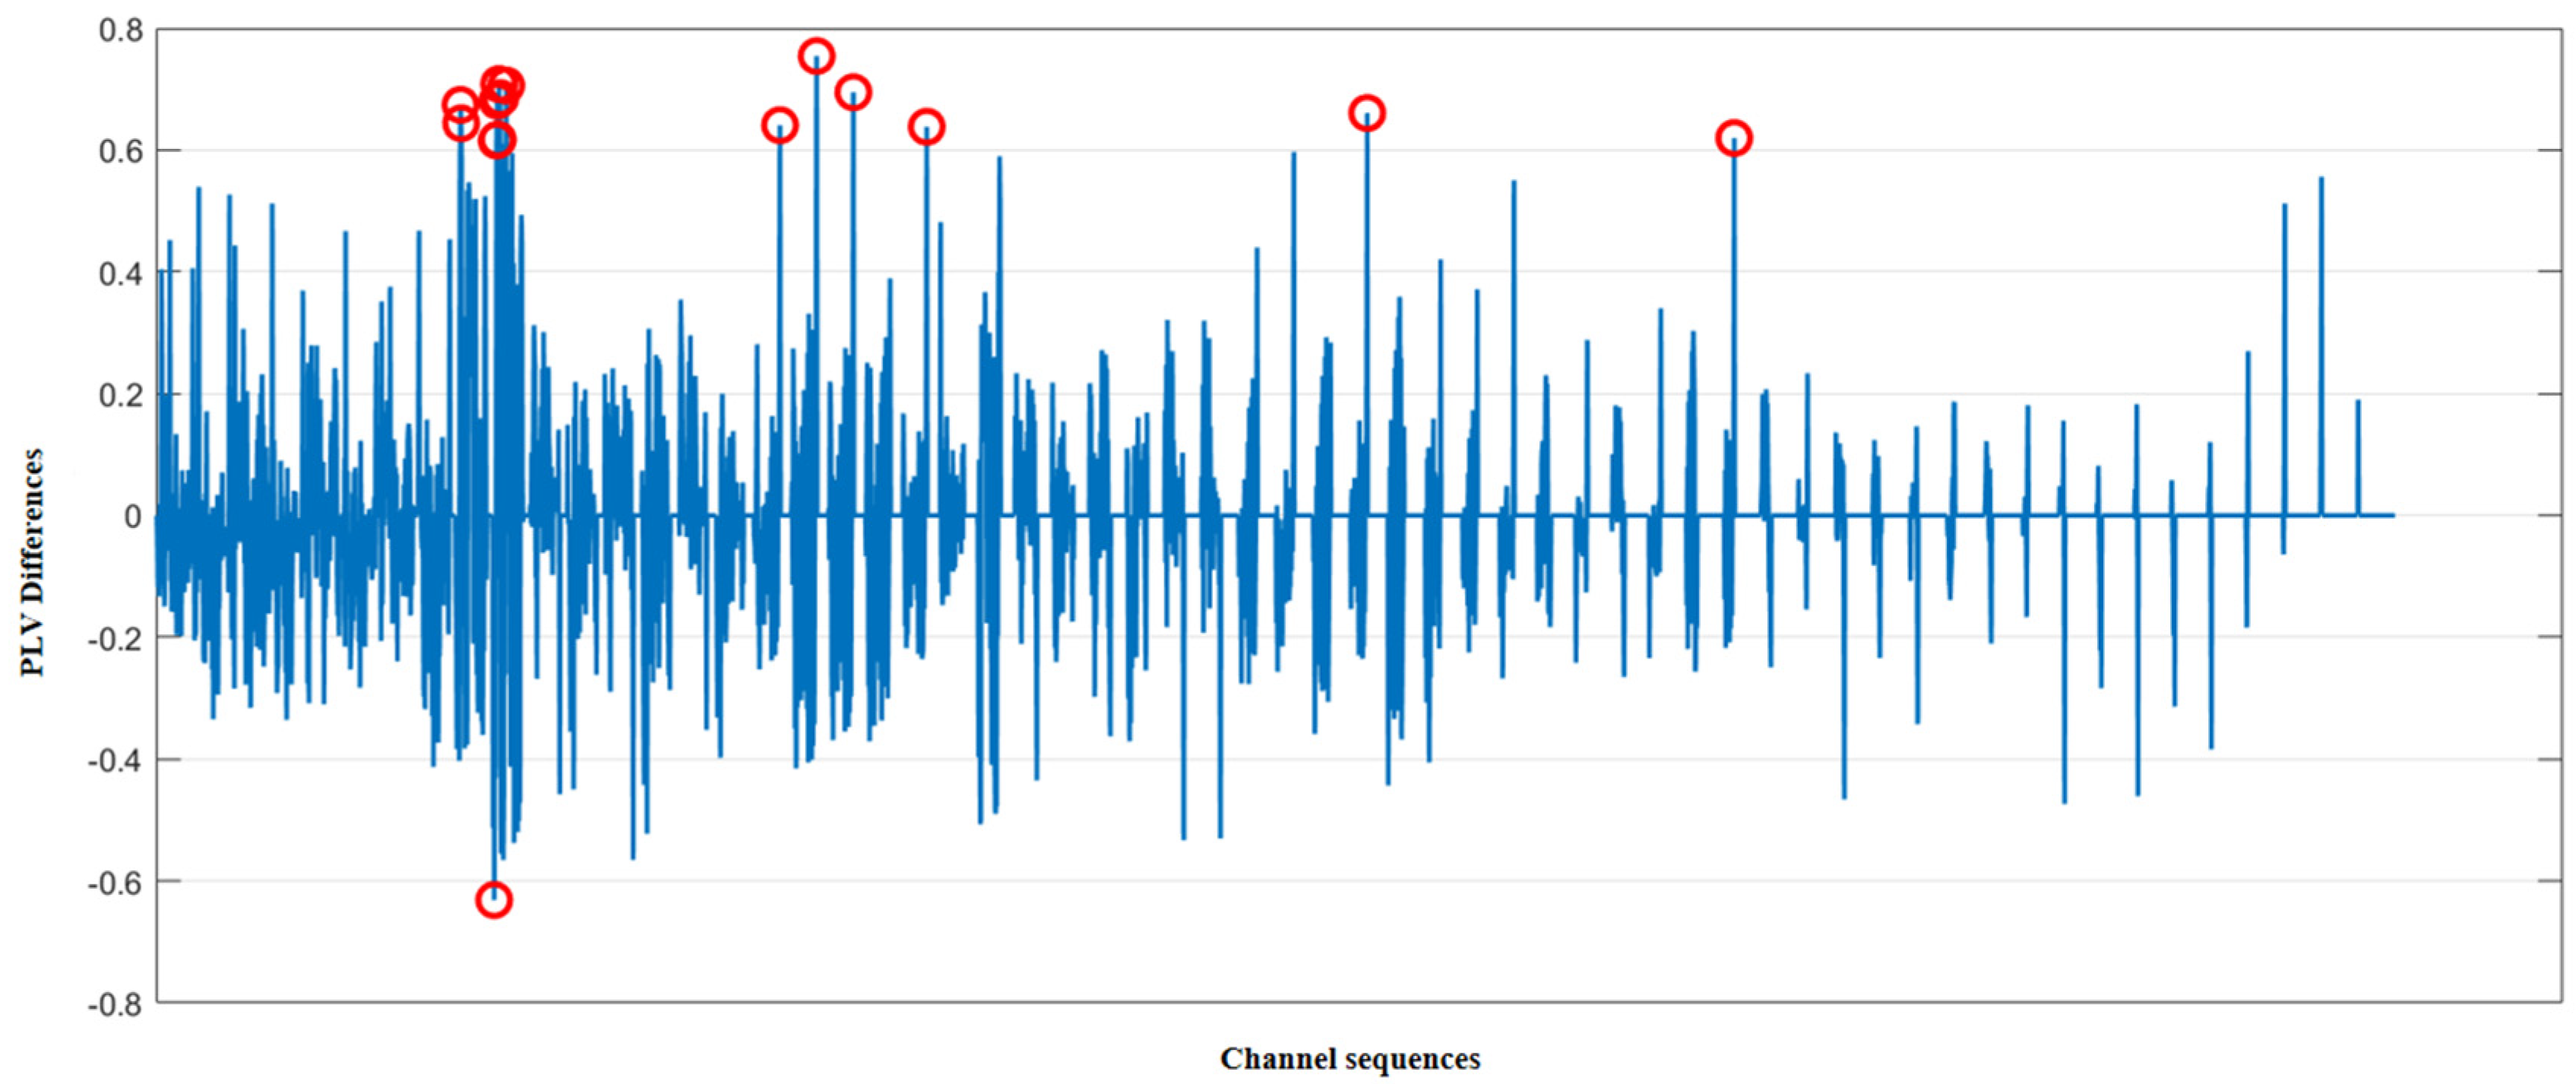
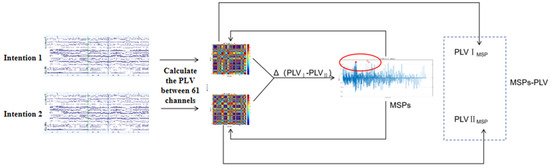
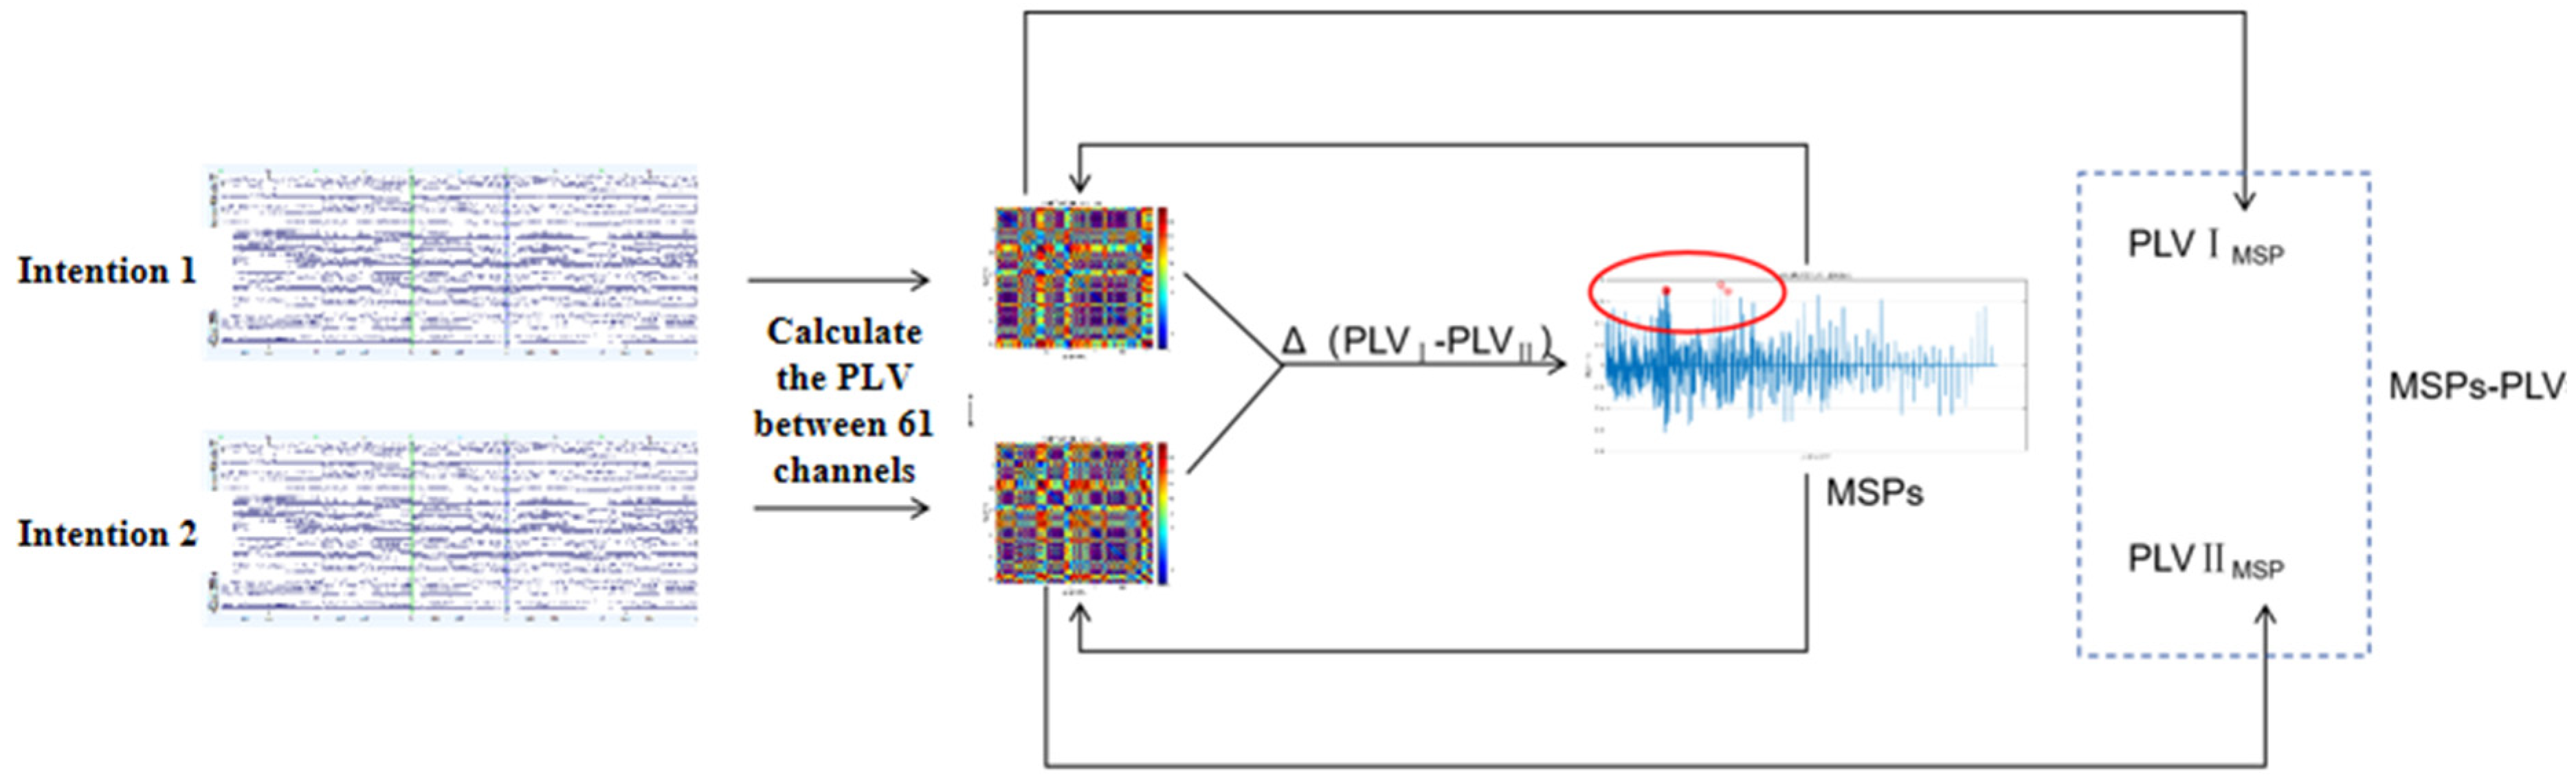
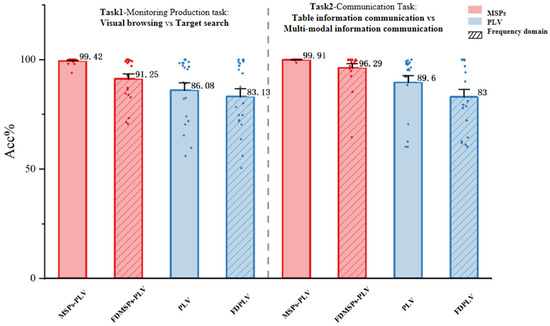
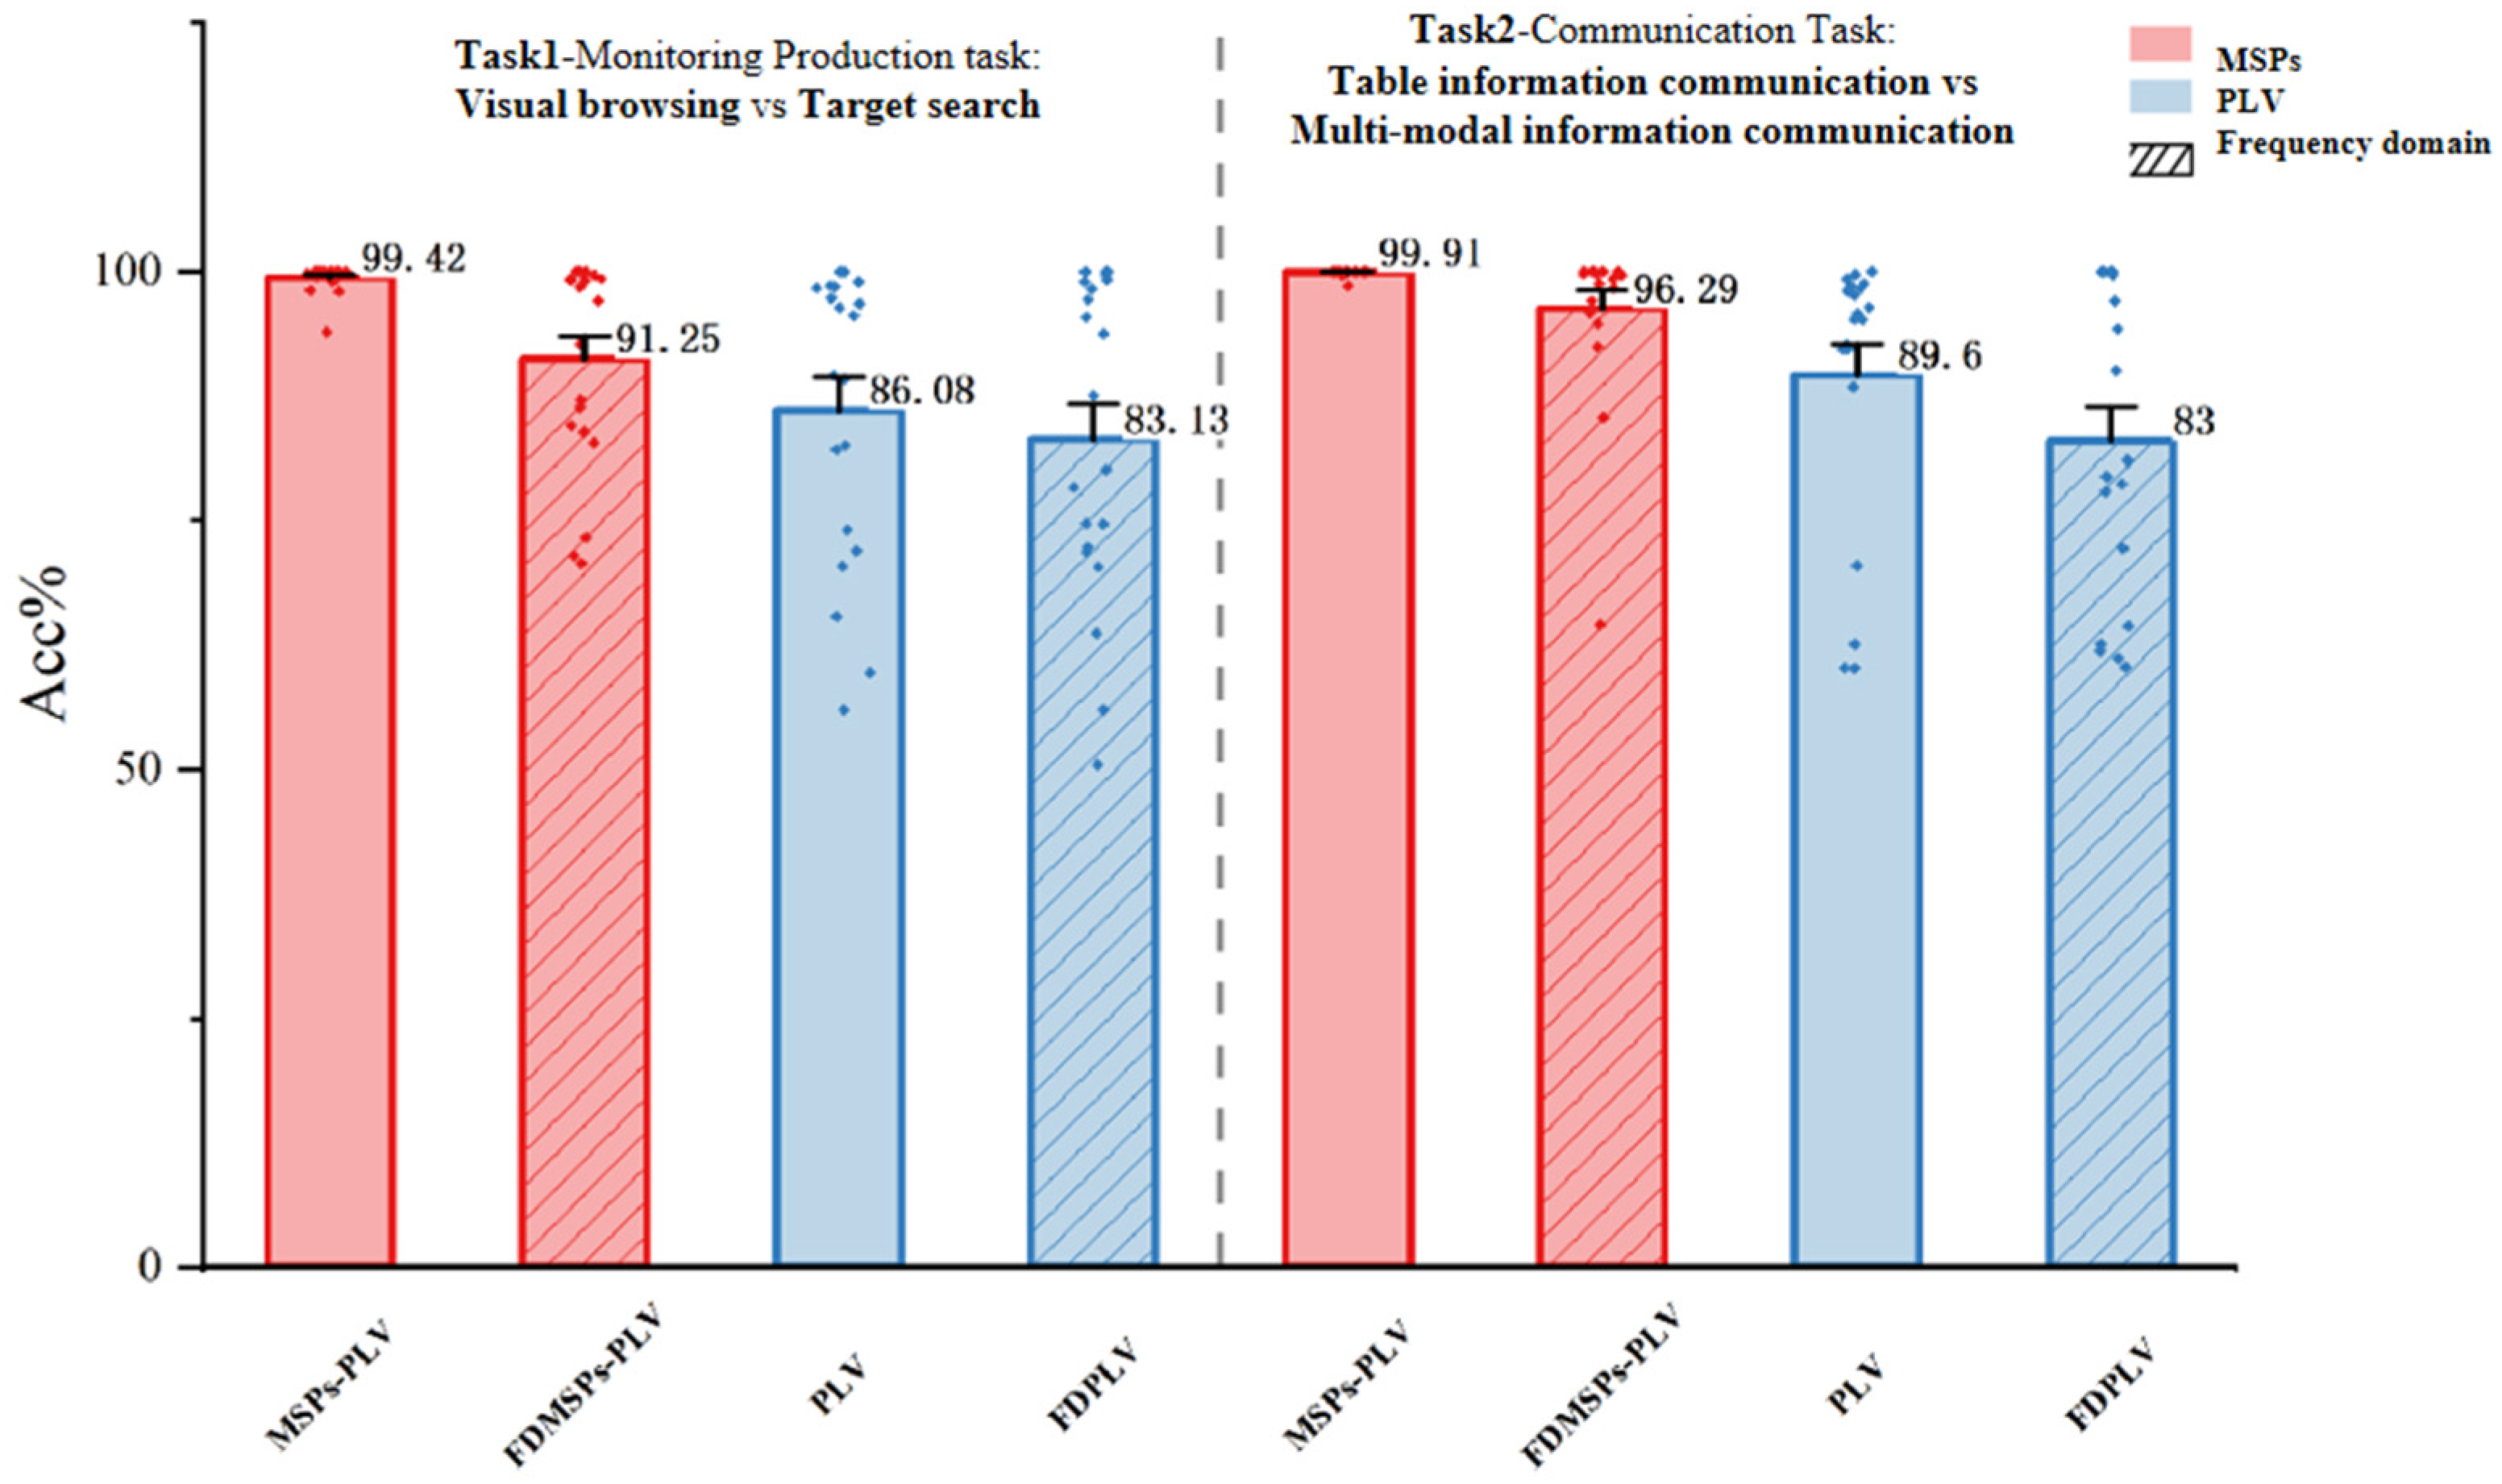
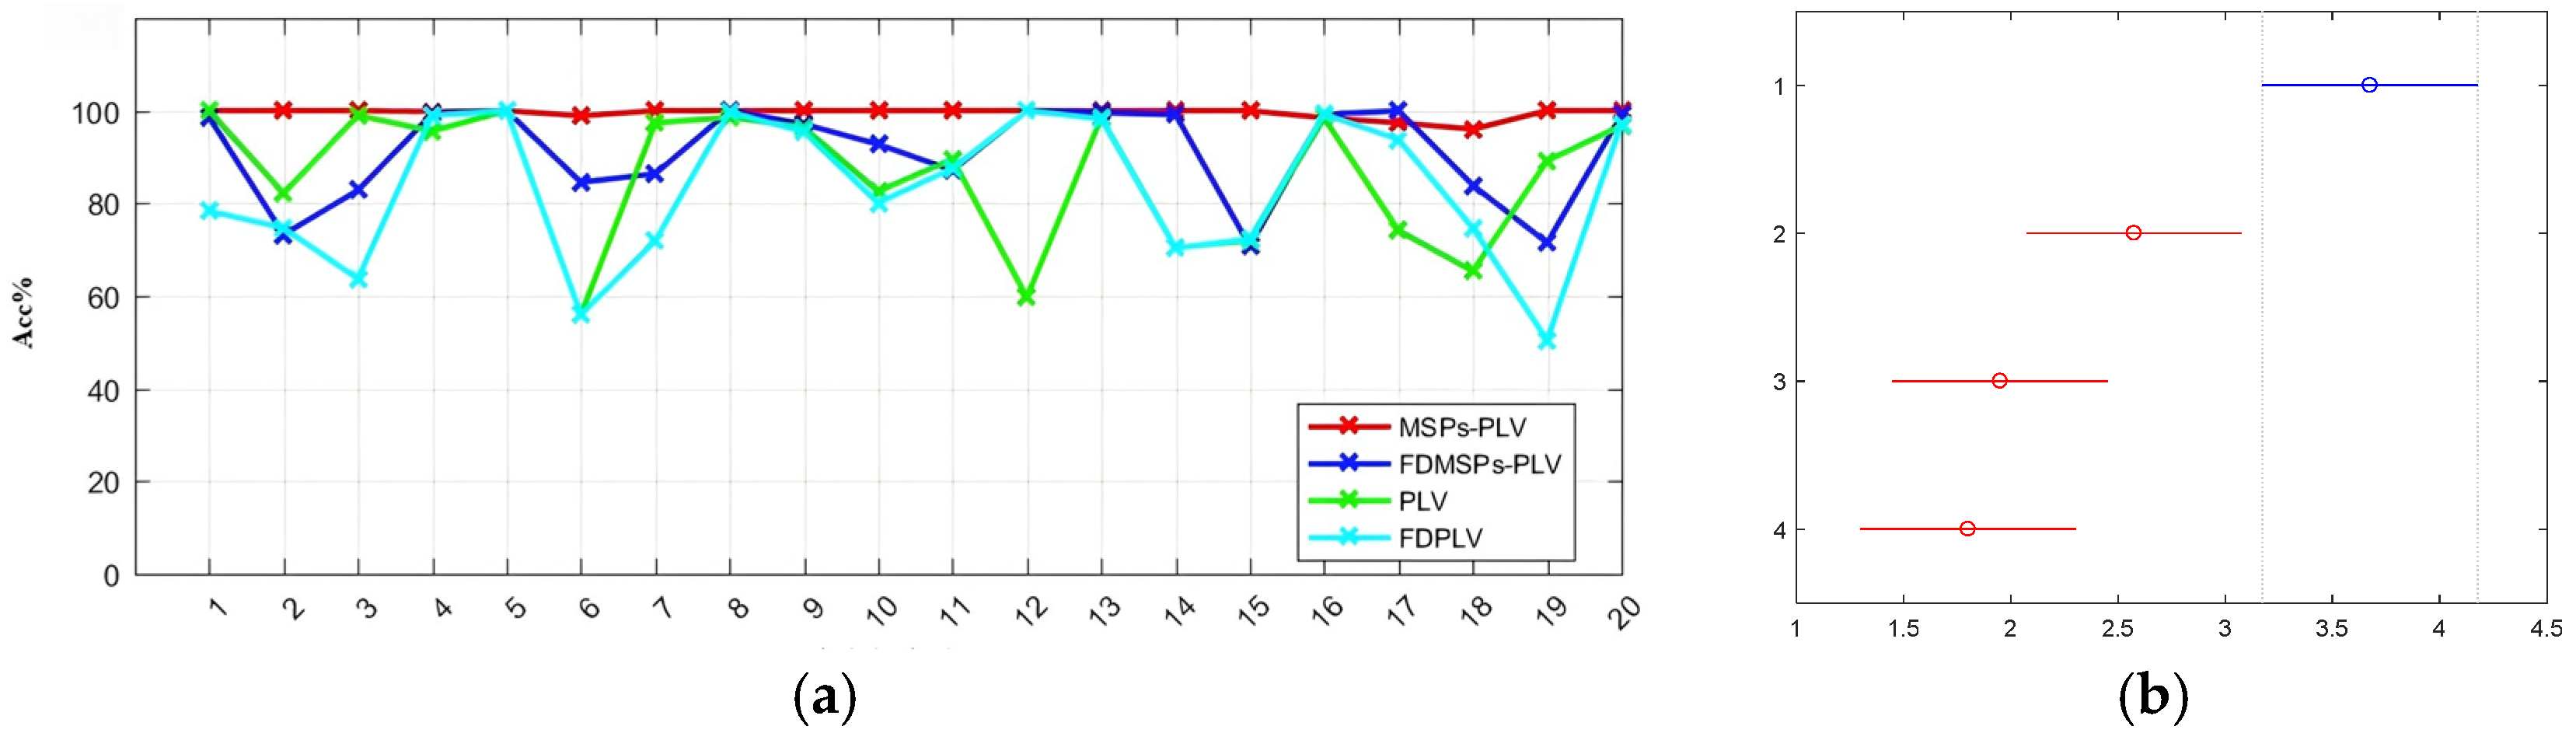
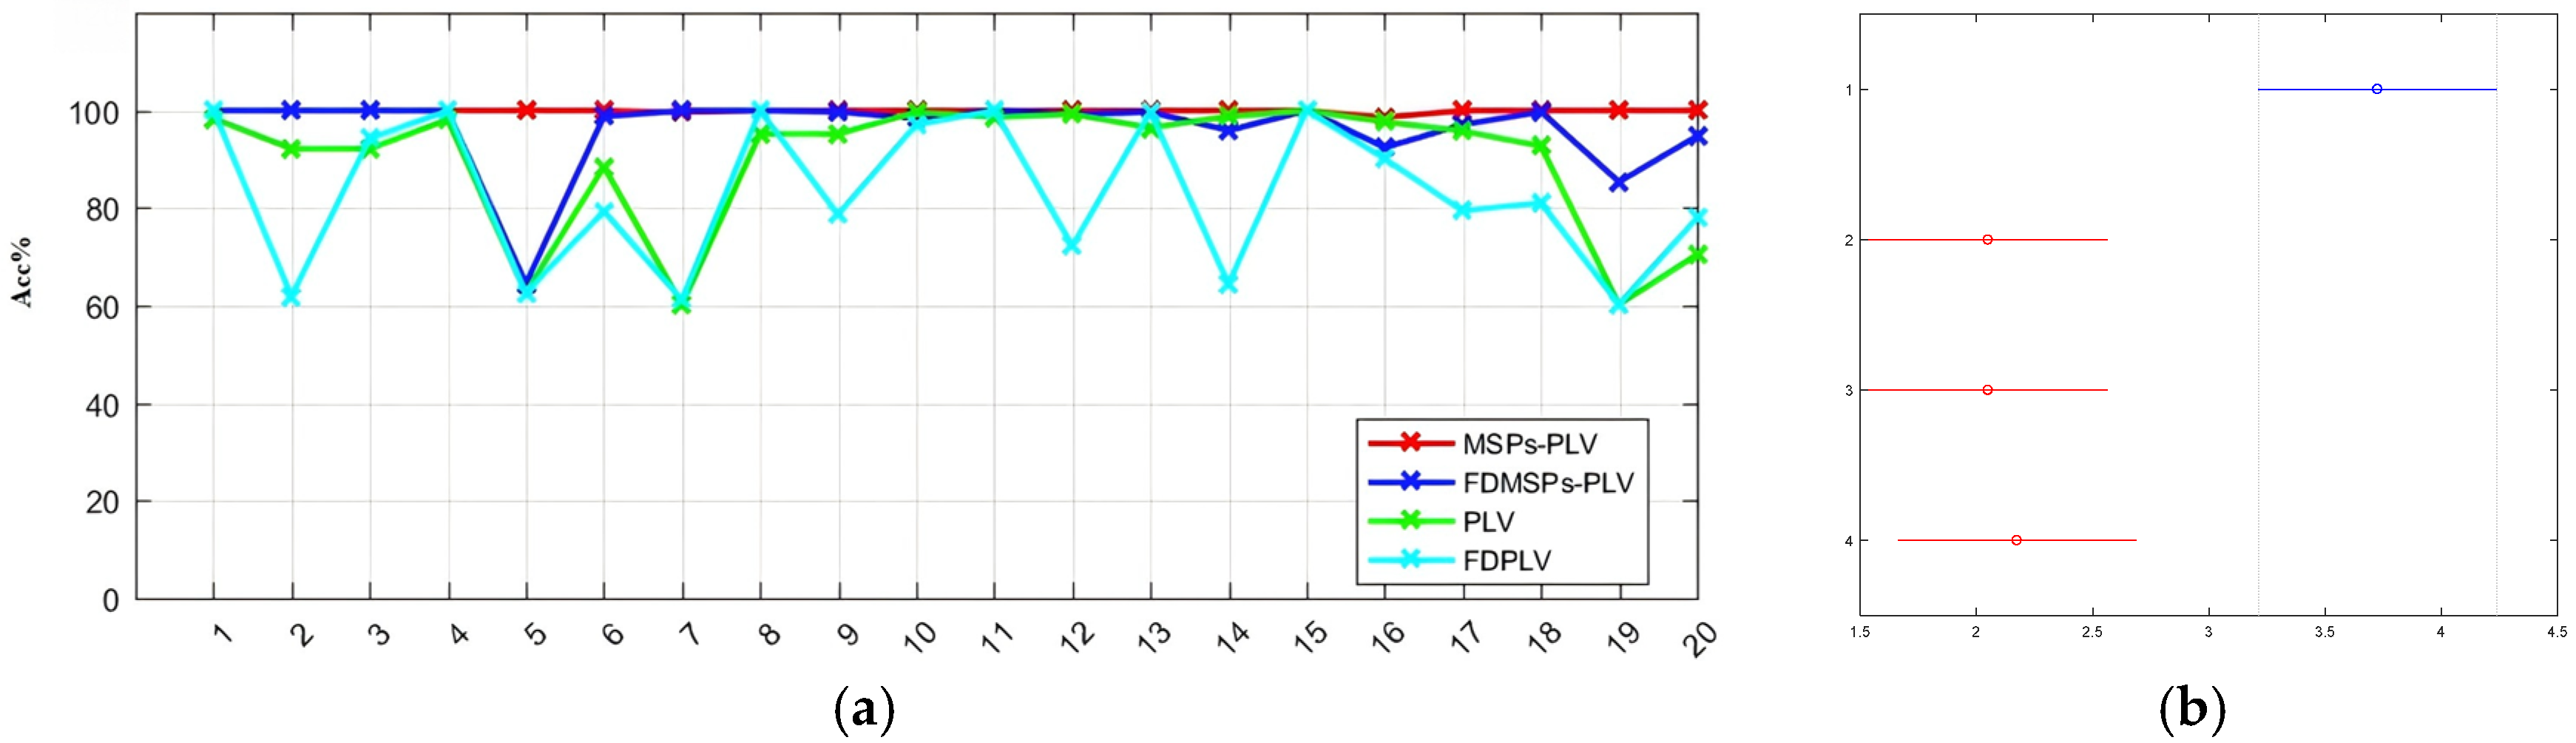
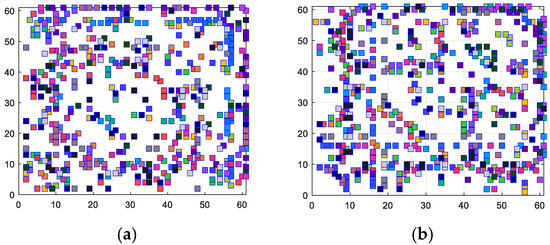
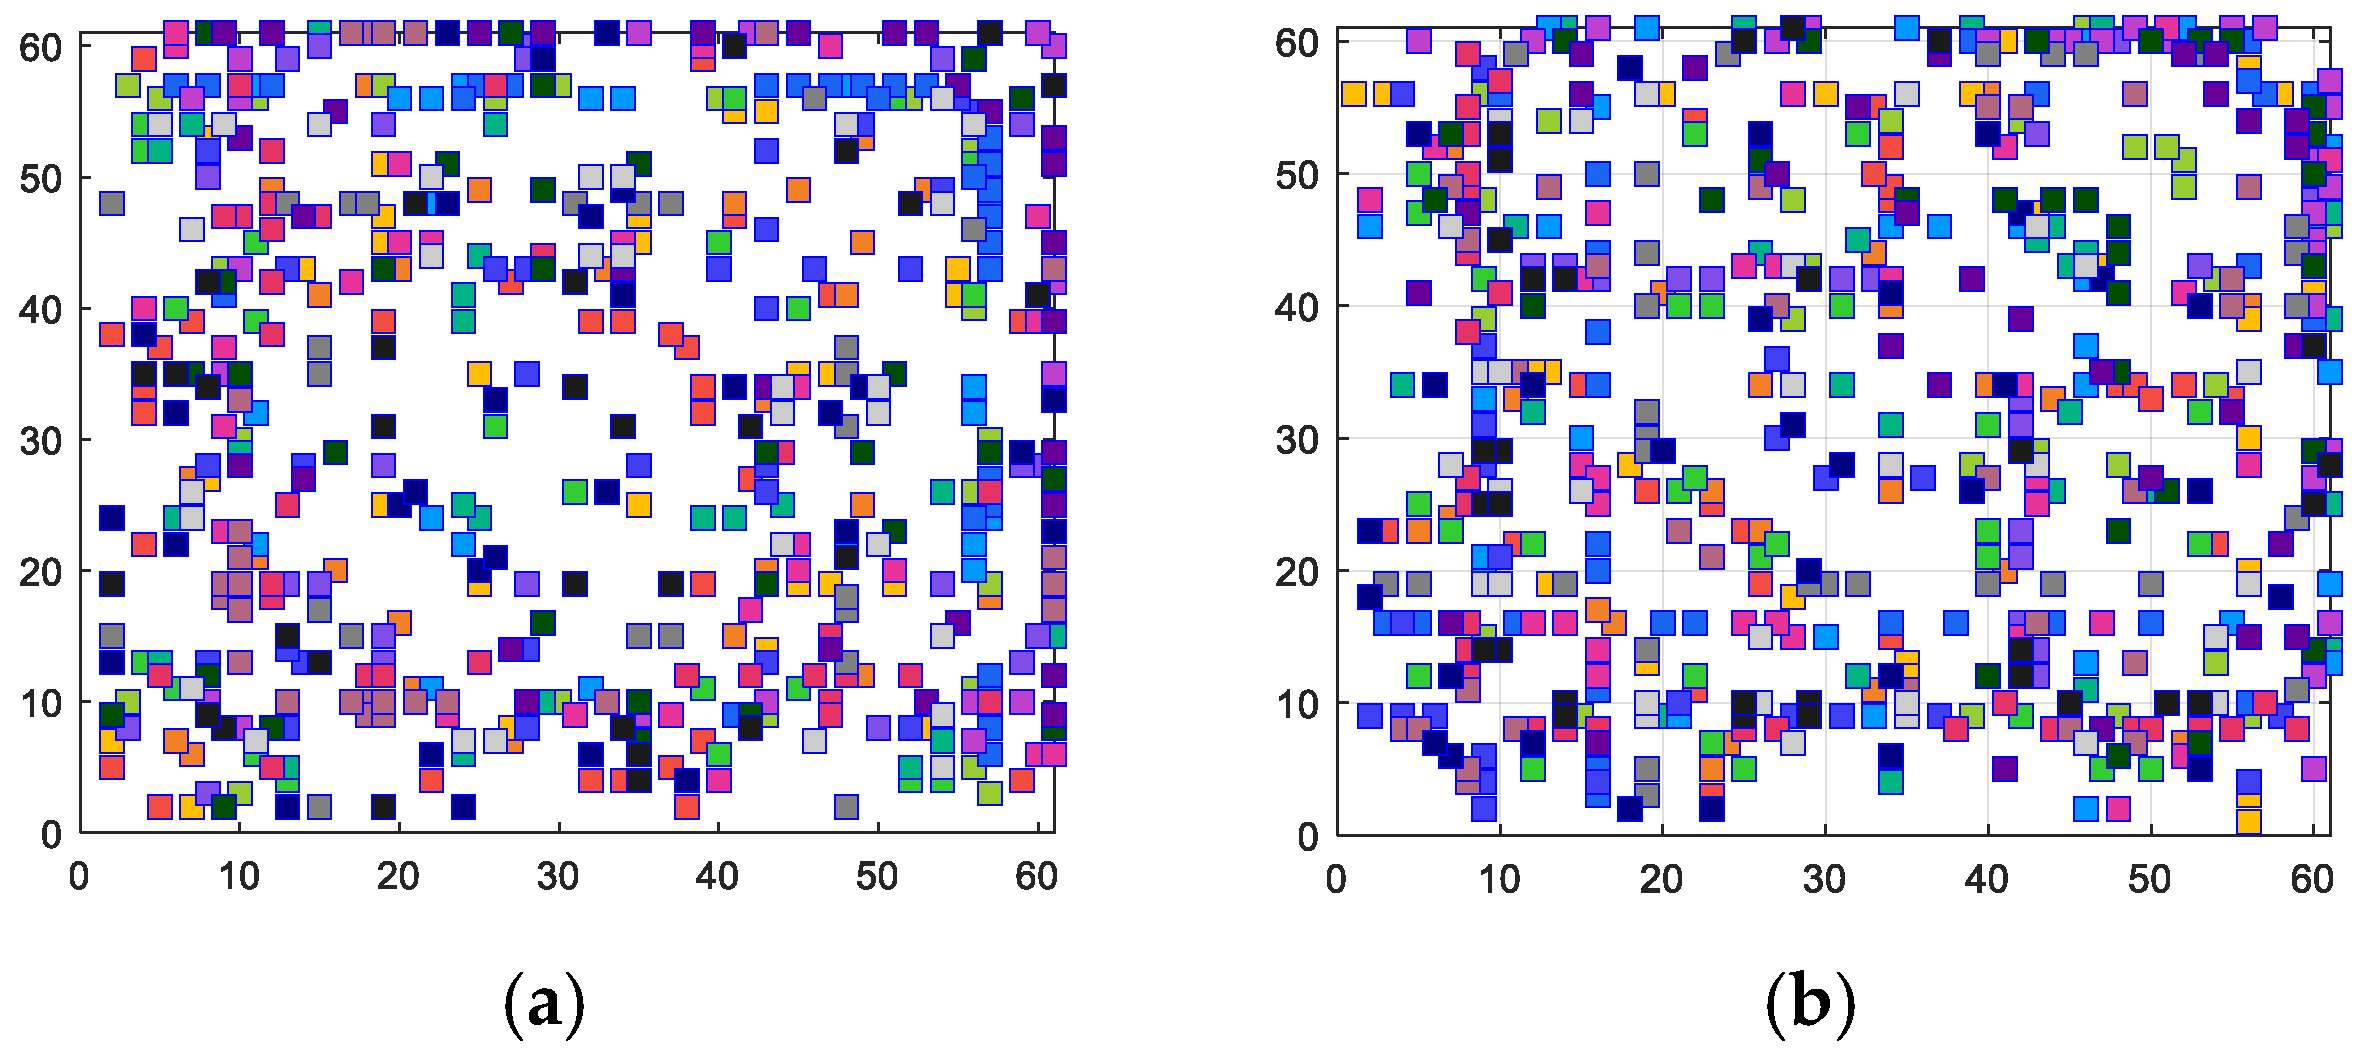
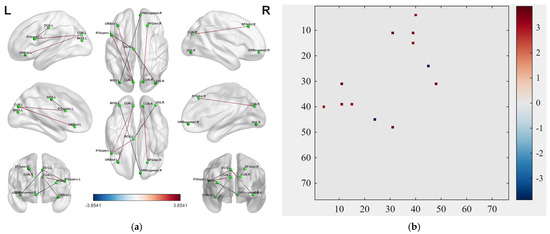
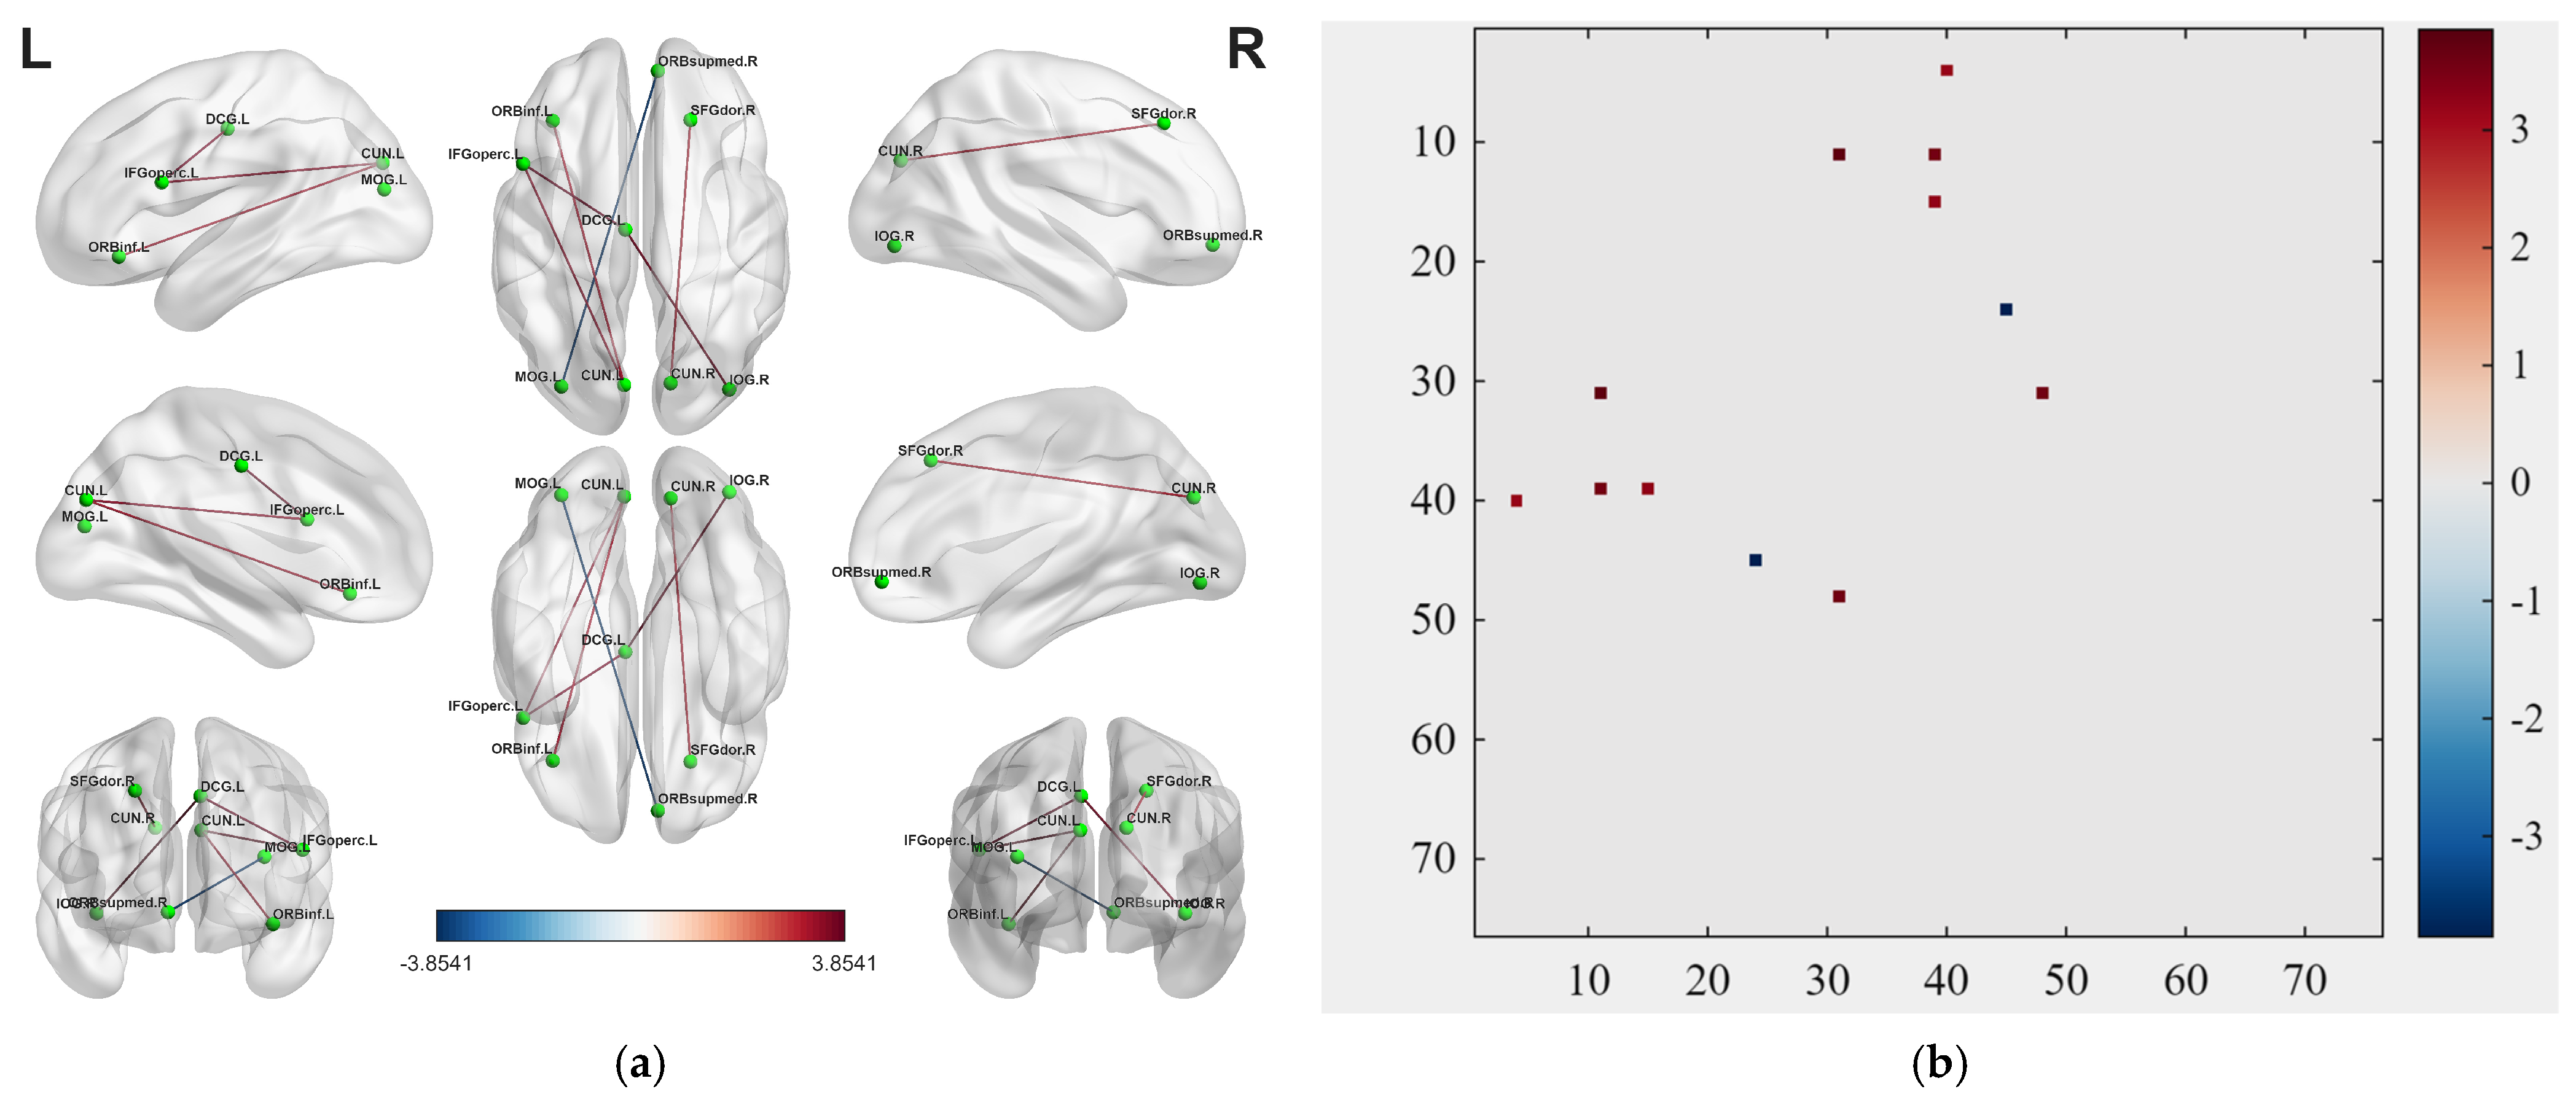
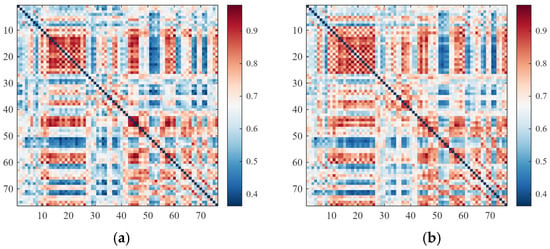
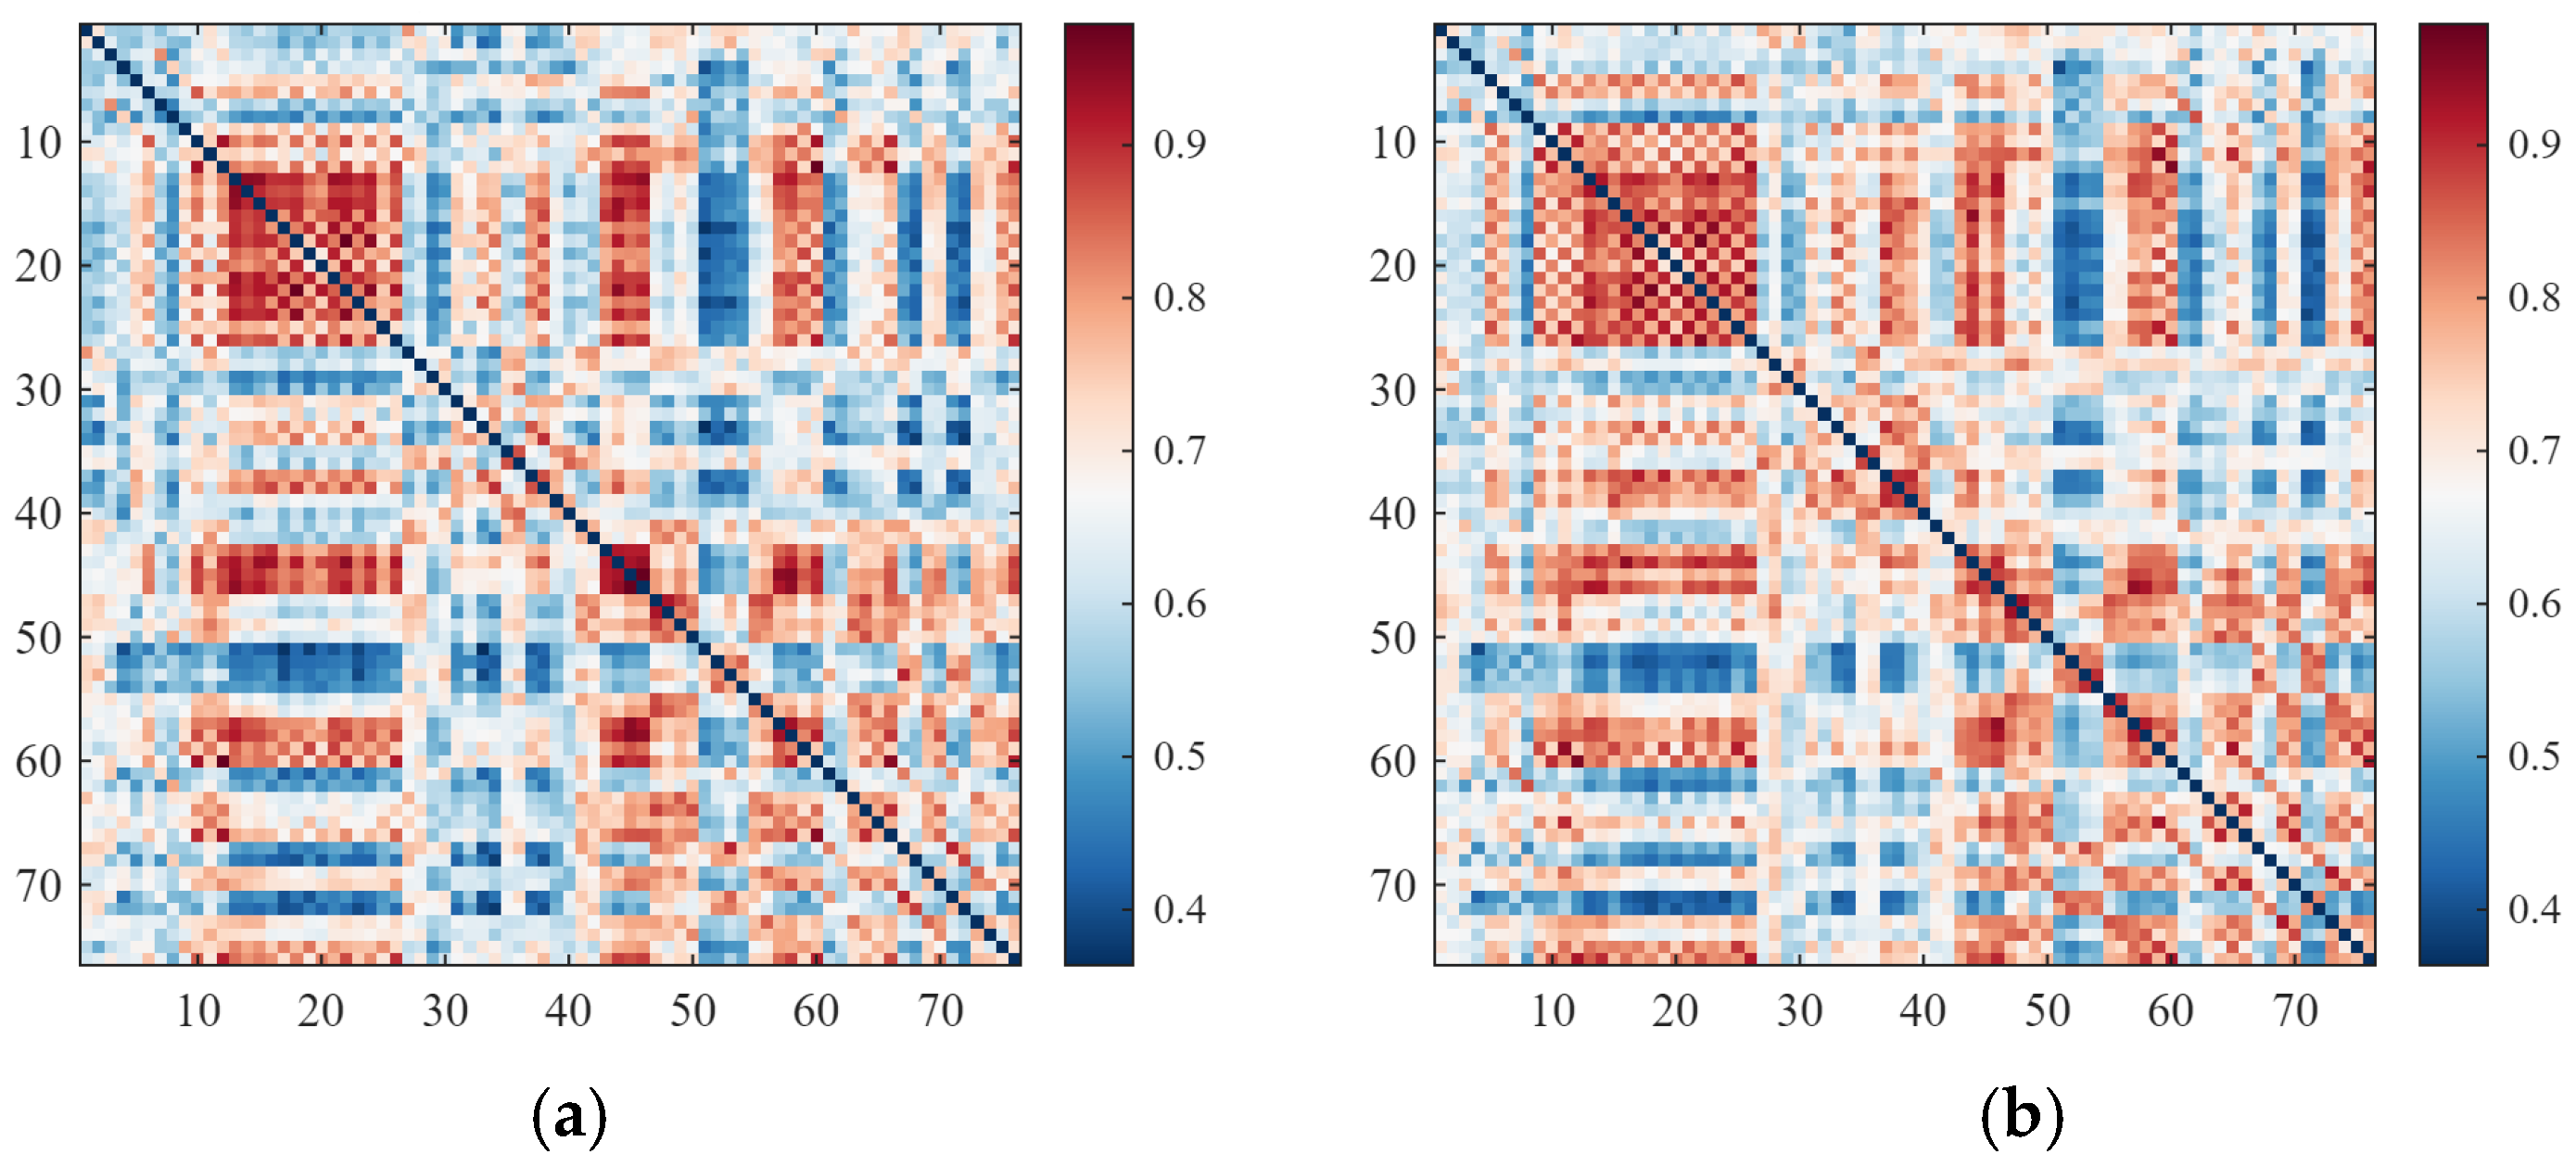
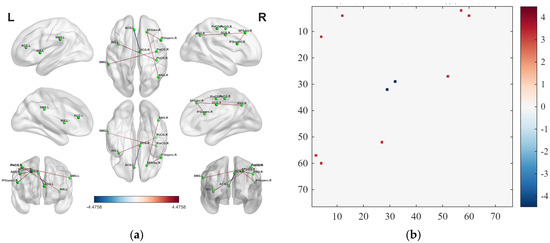
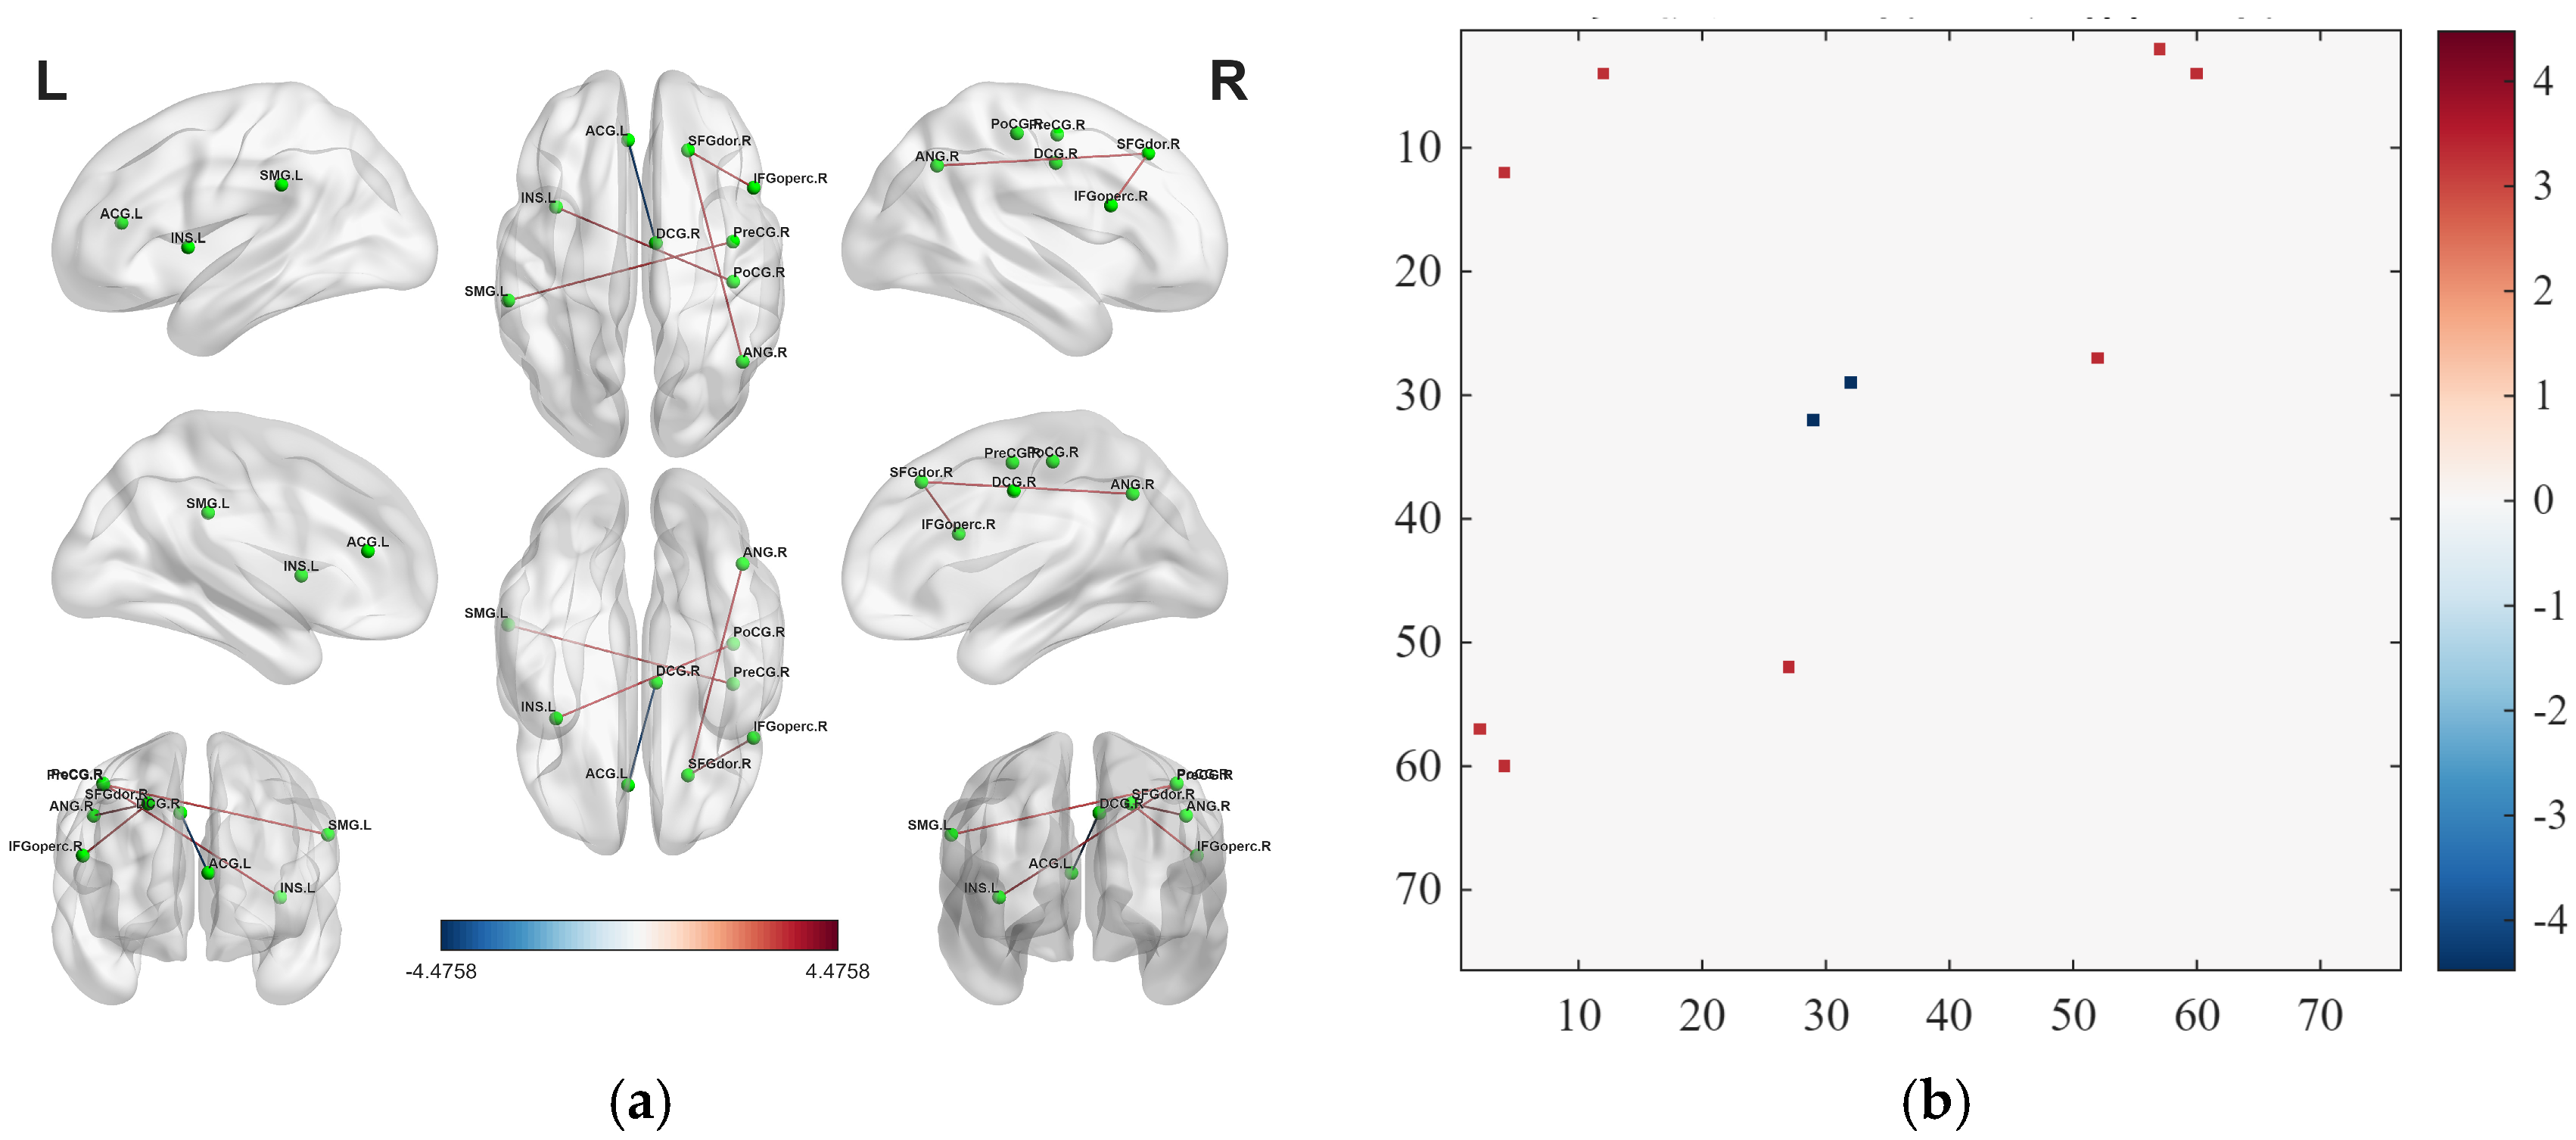
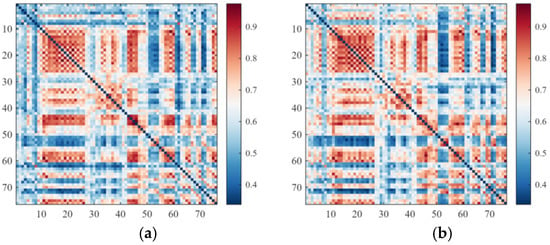
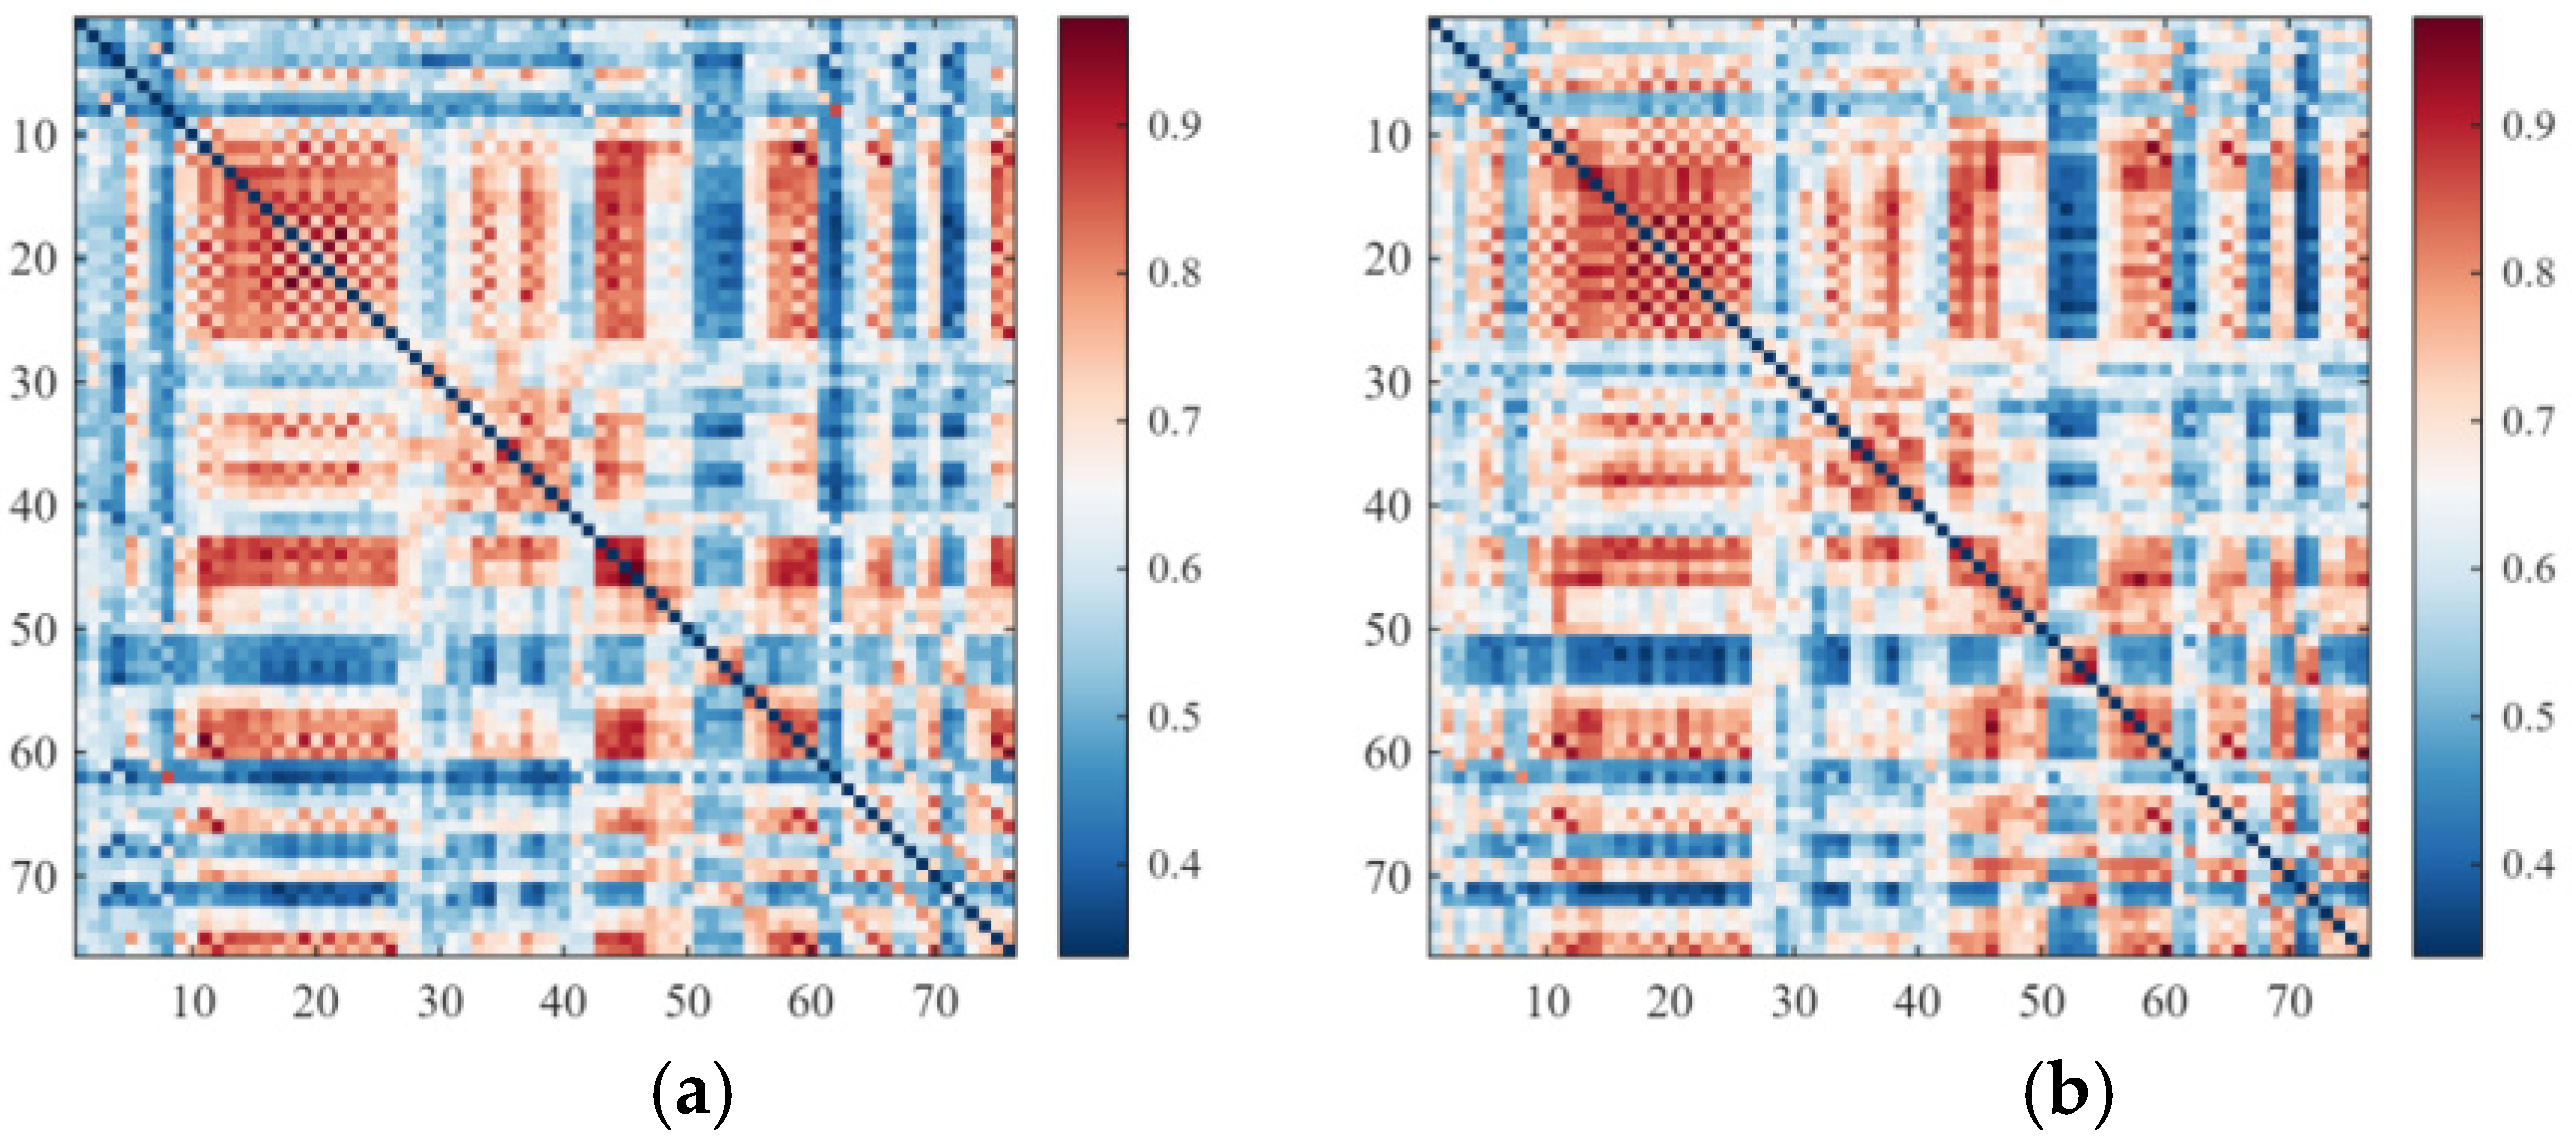
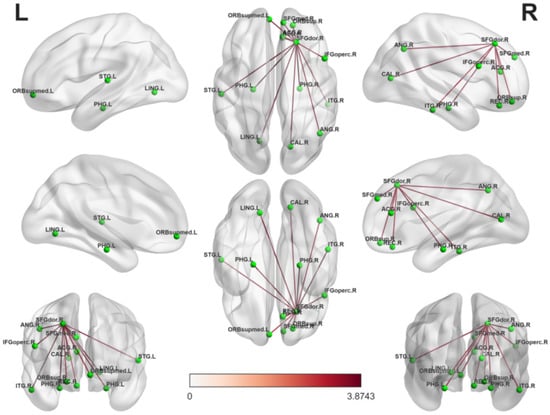
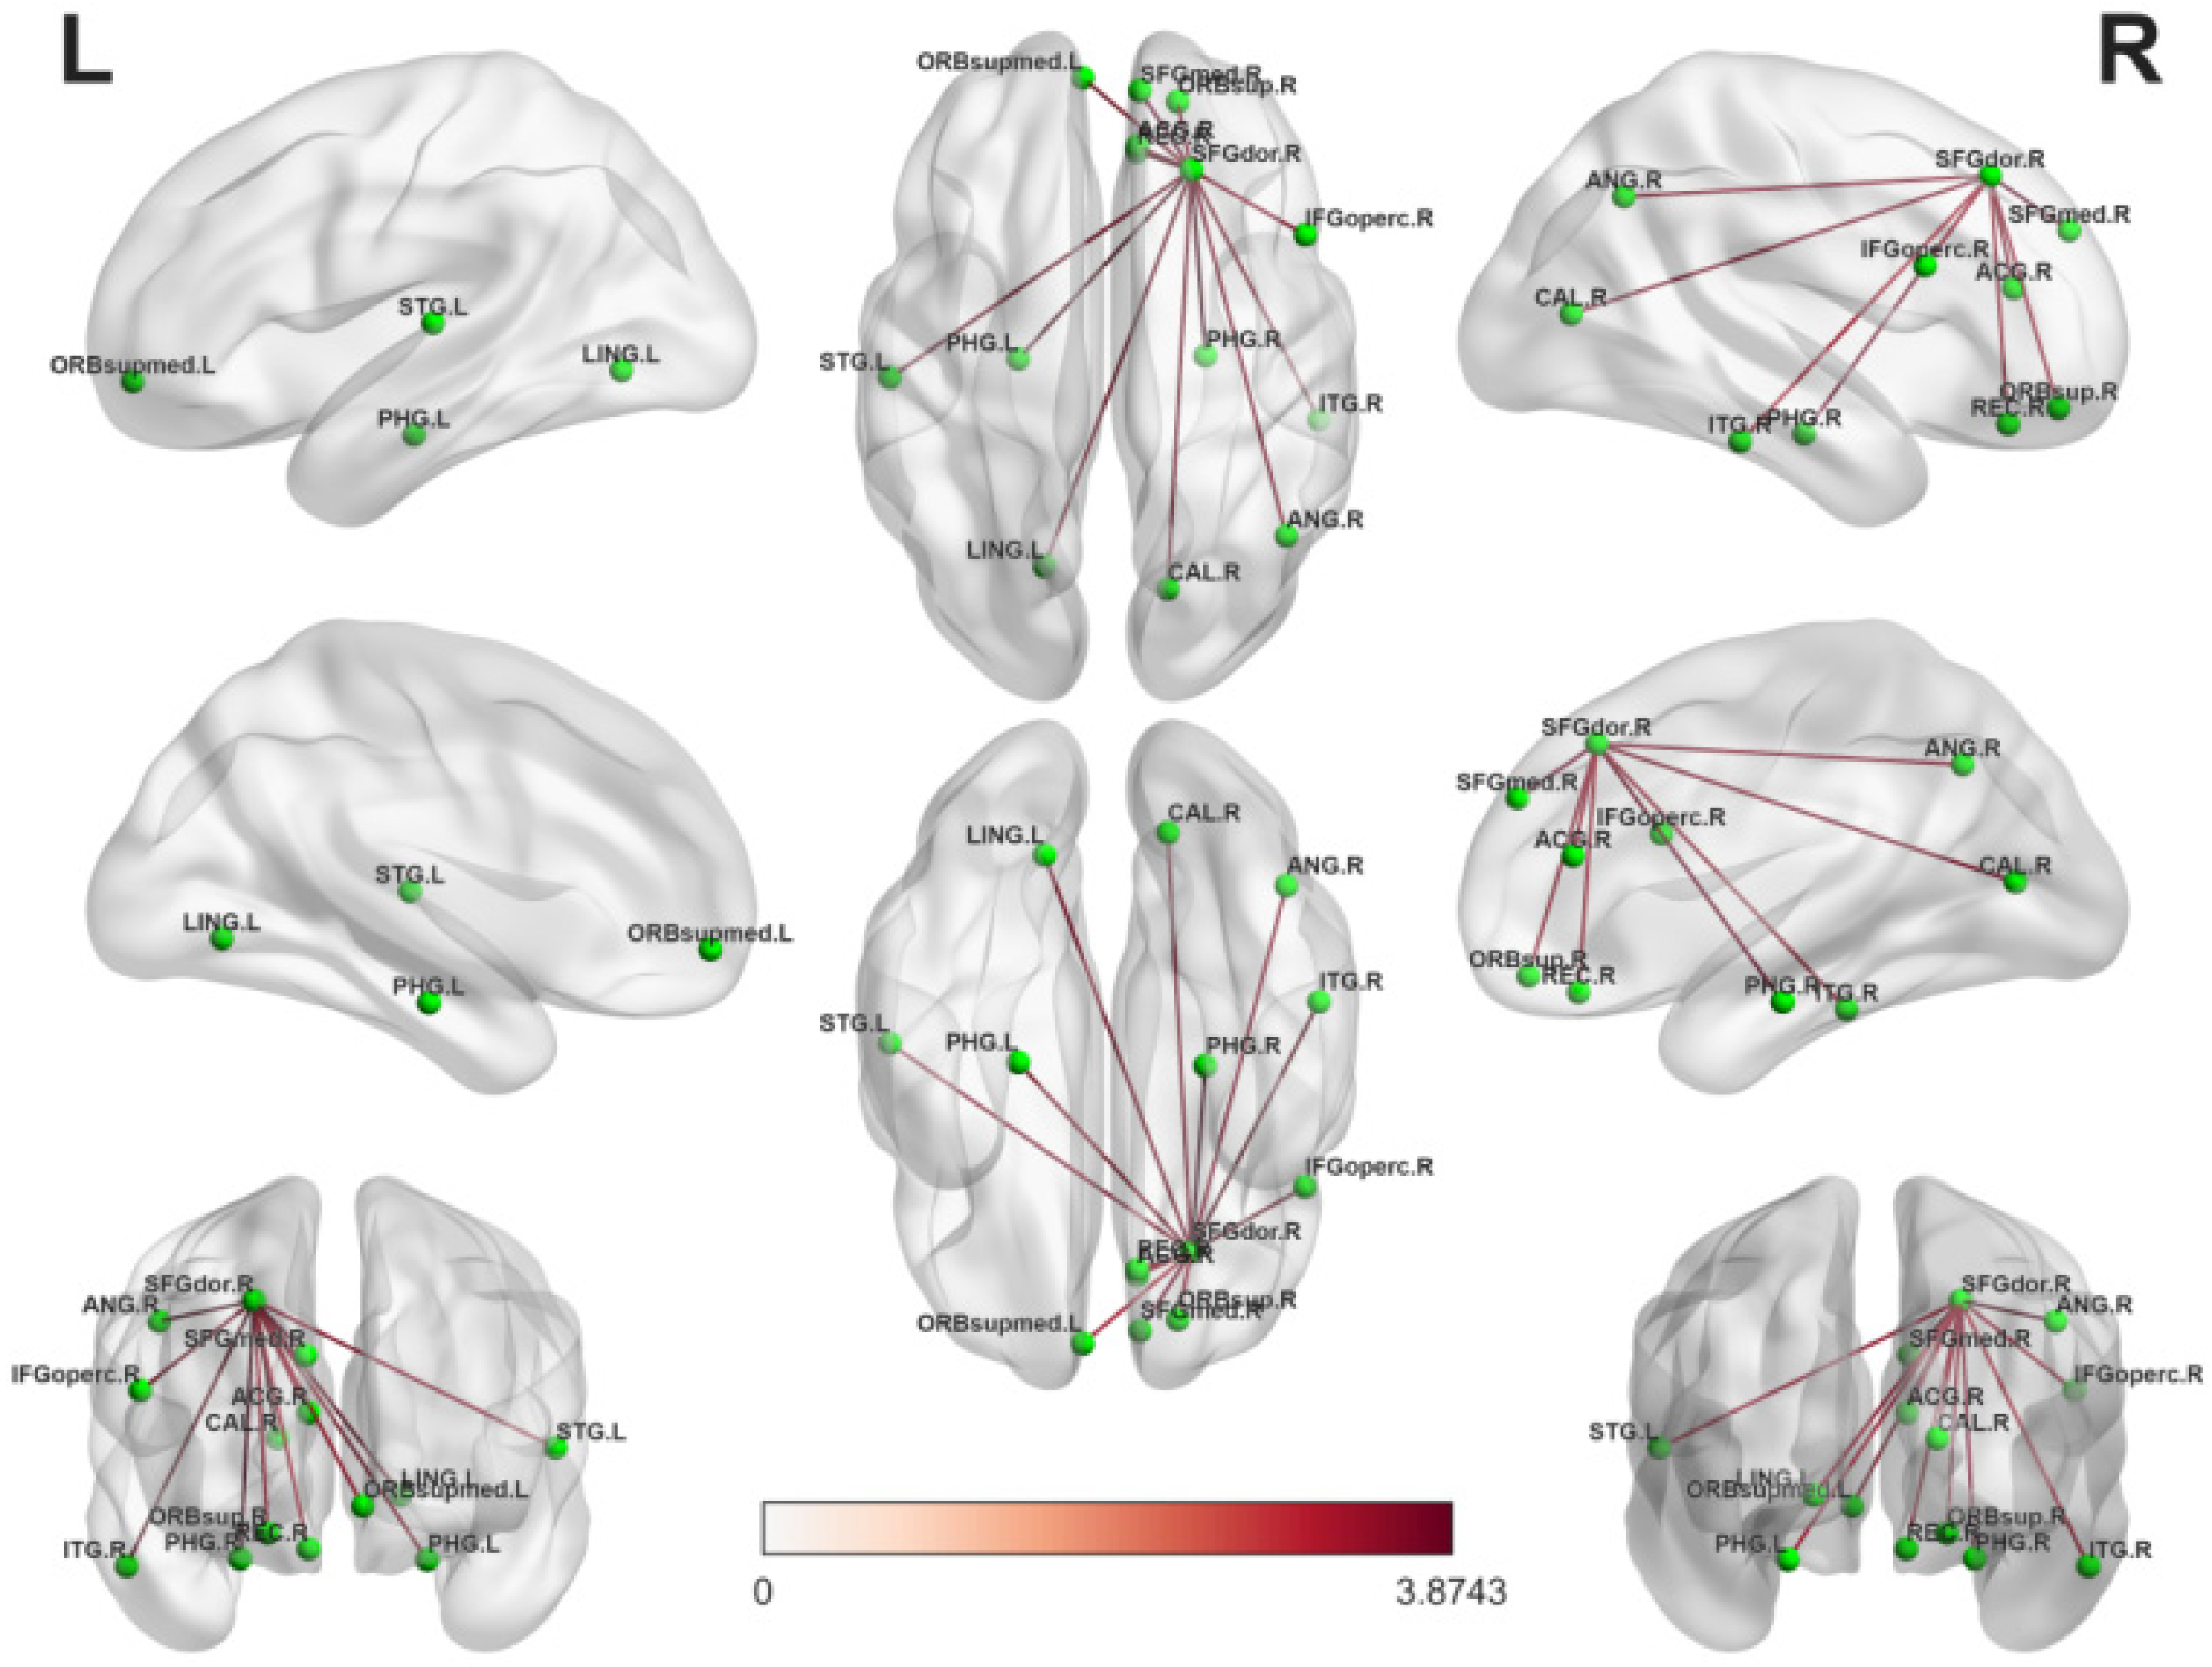
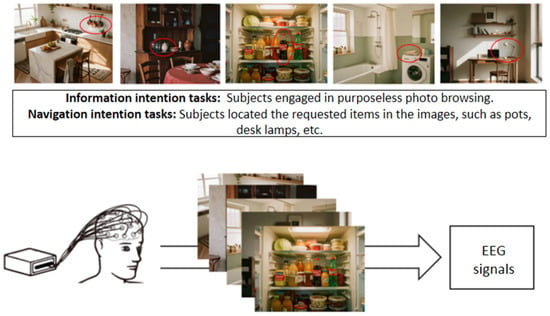
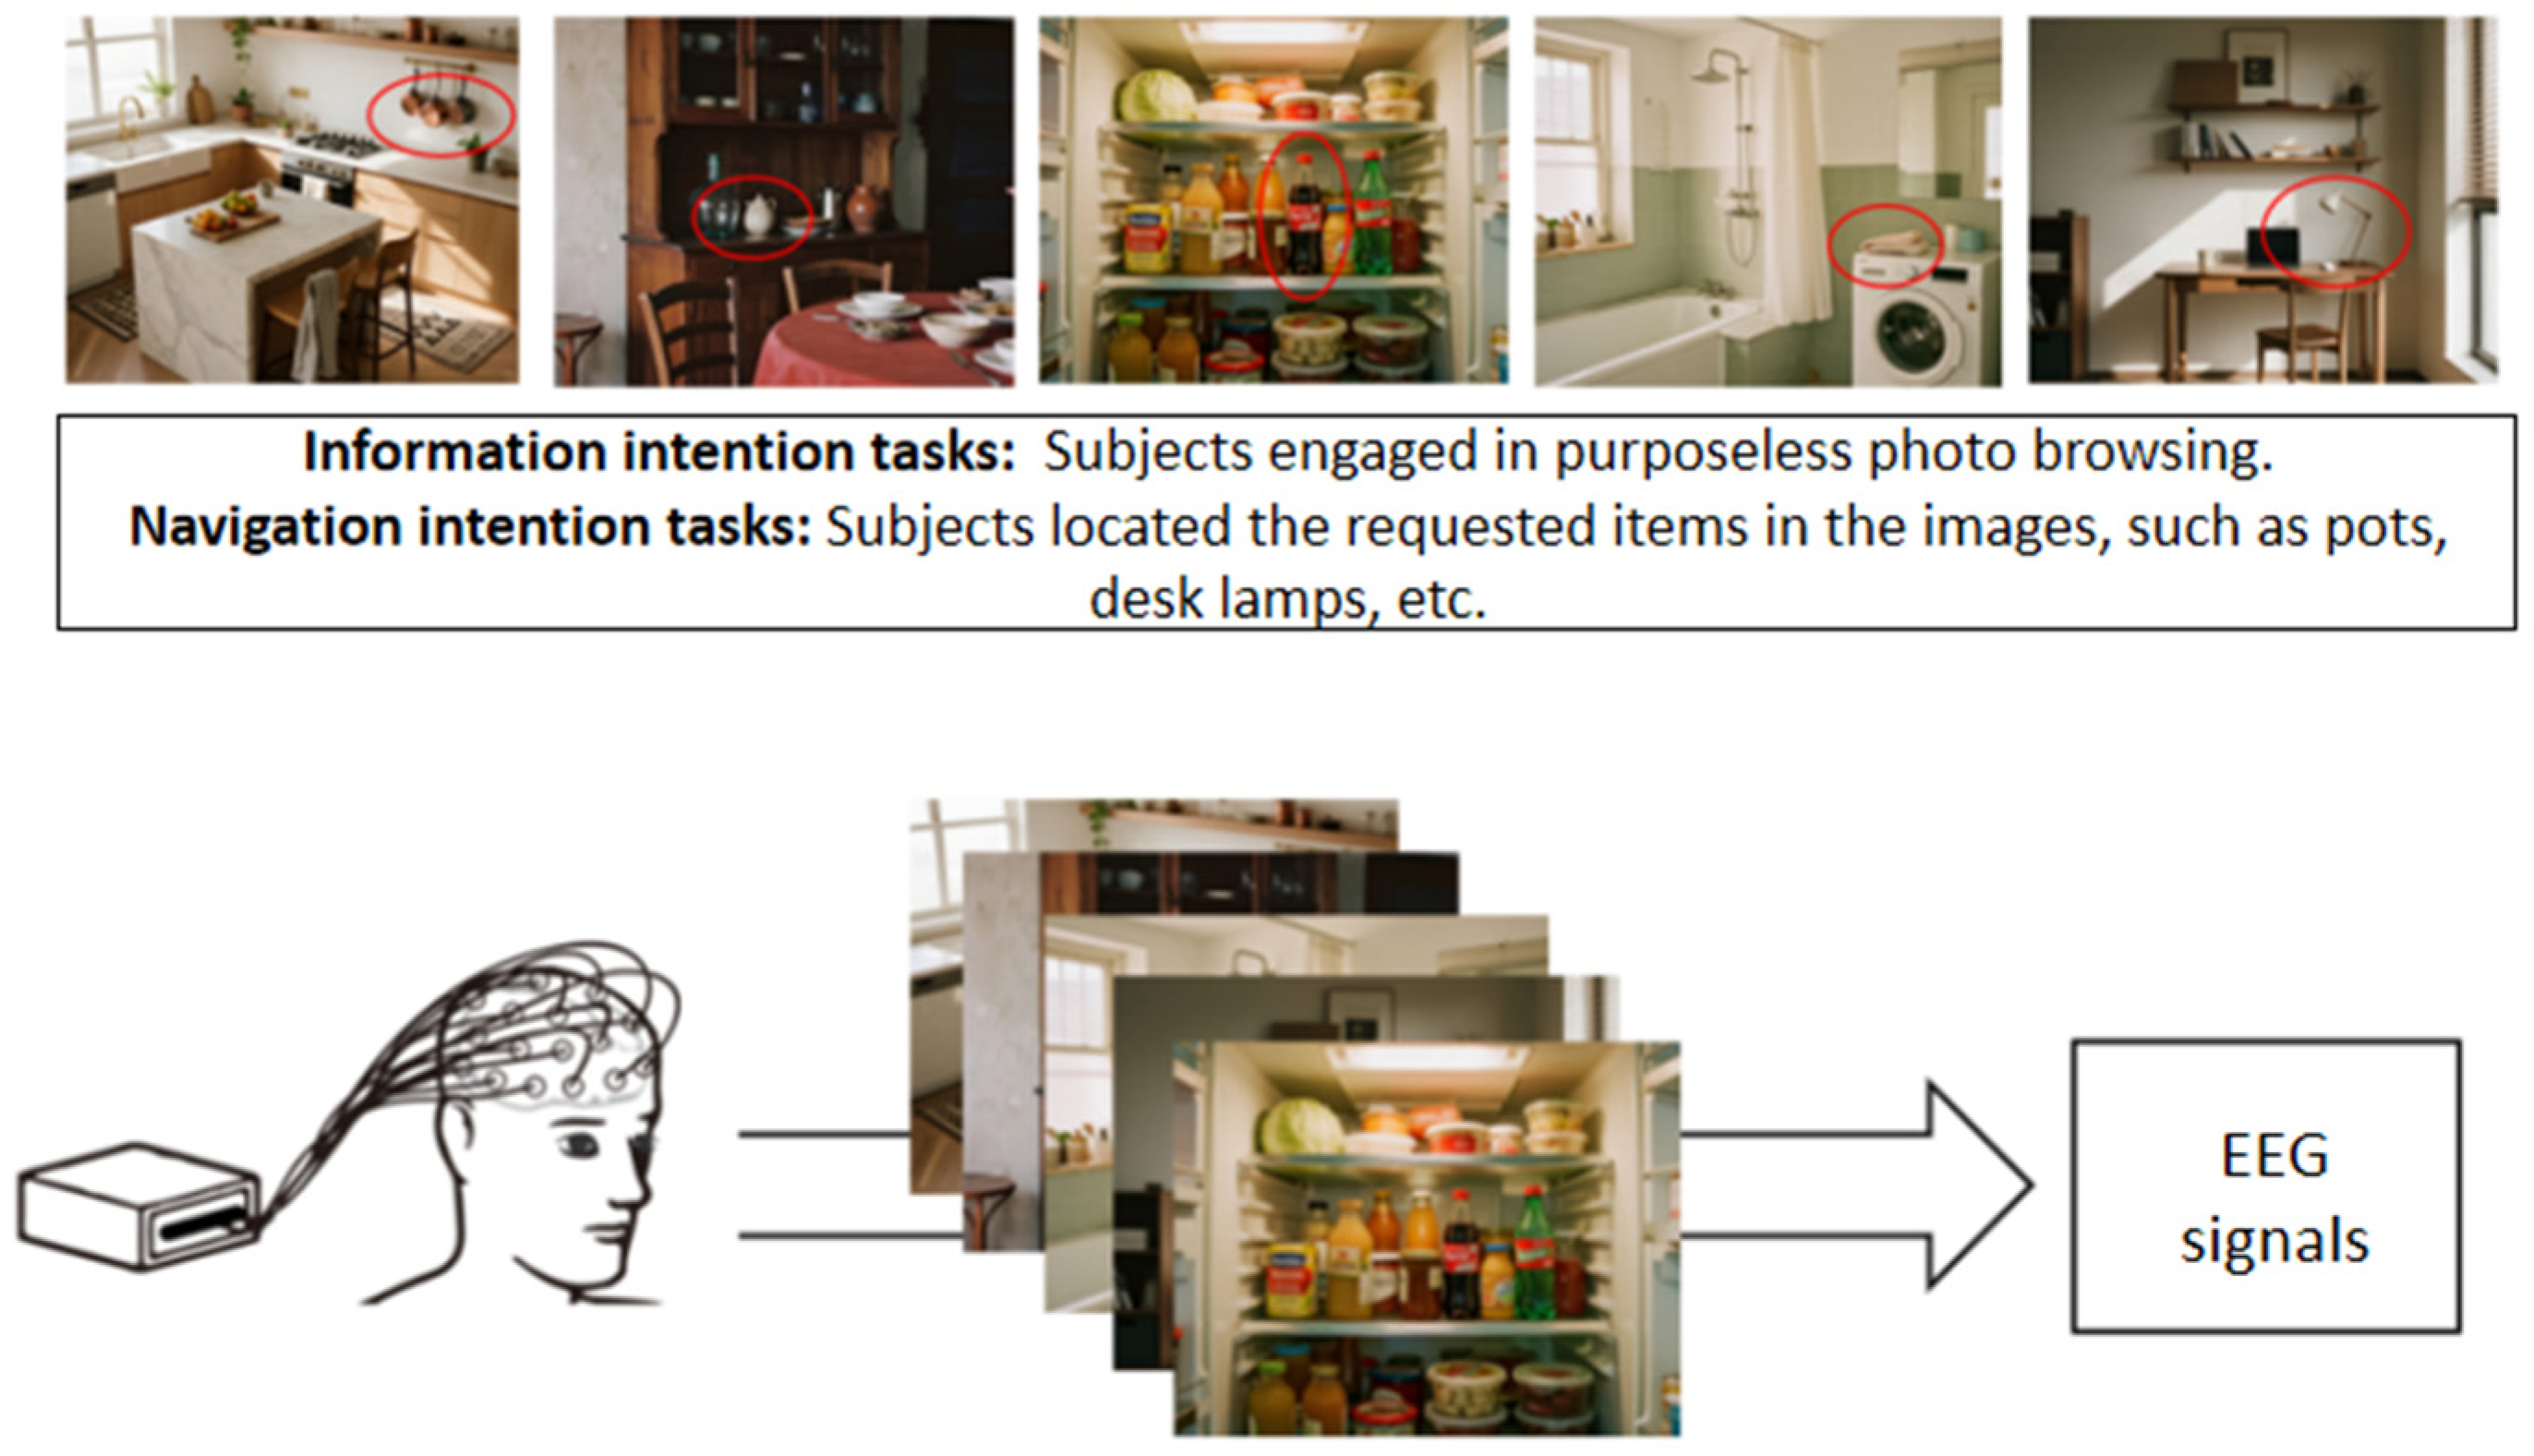

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.