


Abstract
Thermoelectric generators (TEGs) enable compact waste-heat energy harvesting but require high-gain DC–DC conversion due to their low-output voltage for DC microgrid interfacing. This work proposes a novel TEG-supplied two-stage architecture consisting of a perturb-and-observe (P&O)-based MPPT boost converter followed by a modified Z-source converter regulated through an advanced model predictive control (MPC) framework. The modified Z-source topology enables high-voltage gain without extreme duty ratios and mitigates switching losses by eliminating diode reverse-recovery effects via synchronous operation. To enhance dynamic performance, the advanced MPC strategy incorporating an adaptive ripple-based weighting mechanism is applied to the modified Z-source converter and benchmarked against MPC and sliding mode control (SMC). Simulation results under multiple disturbance scenarios, including hot-side and cold-side temperature variations, multi-condition disturbances, coupling-factor variation, and measurement noise, demonstrate that the proposed system maintains stable 400 V regulation at a 100 W output level. In contrast, MPC exhibits switching frequency deviations that increase switching losses during transient operation, while SMC suffers from significant voltage deviations under source variations. The proposed strategy maintains tight voltage regulation with nearly fixed-frequency operation around 50 kHz, providing a new perspective for TEG researchers while supporting sustainable waste-heat energy utilization.
1. Introduction
The global energy transition increasingly emphasizes emission reduction, energy efficiency, and the integration of renewable energy sources due to growing concerns over energy security. Rising energy demand, fossil fuel price volatility, and the accelerating impacts of climate change have made energy security one of the most critical challenges of the modern era [1,2]. In this context, microgrid technology has emerged as a key enabler for renewable energy systems by facilitating the efficient integration and management of distributed energy resources [3,4]. Although renewable energy technologies offer a cleaner and more sustainable pathway by reducing greenhouse gas emissions, the second law of thermodynamics dictates that all energy conversion systems inevitably dissipate a portion of input energy as waste-heat [5]. This inevitable energy loss, often released to the environment without being utilized, presents a significant opportunity to enhance overall system efficiency and generate additional sustainable power through waste-heat recovery technologies.
One of the most common methods for utilizing waste-heat is converting it into electrical energy using Organic Rankine Cycle (ORC) systems. For this reason, many studies have investigated ORC-based hybrid systems to improve energy recovery efficiency and overall system performance [6,7]. However, ORC systems rely on mechanical components, which introduce acoustic noise, increase system complexity, and require considerable installation space [8]. In contrast, thermoelectric generators (TEGs), based on the Seebeck effect discovered in 1821, enable silent and direct conversion of low-grade waste-heat into electrical energy without moving parts, offering a compact, reliable, and maintenance-free solution for sustainable power generation [9]. TEGs are widely utilized in waste-heat recovery systems for power generation across a broad range of heat sources. In renewable energy applications, solar energy and biomass systems provide suitable thermal inputs for TEG-based energy harvesting [10]. Non-renewable applications include automobile and internal combustion engines, where TEGs are used for waste-heat recovery [11]. Additionally, industrial processes offer high-temperature waste-heat sources that can be exploited by TEGs to improve overall energy efficiency.
Despite their advantages, TEGs inherently suffer from low conversion efficiency, low-output voltage, and limited power density due to their small Seebeck coefficient and low temperature gradients. To mitigate efficiency limitations, TEGs should be operated close to their full capacity by maximizing power extraction through optimal load matching [12]. Maximum power transfer is achieved when the load resistance matches the internal resistance of the TEG. When the TEG is directly connected to a mismatched load, its conversion efficiency is consequently reduced. To avoid impedance mismatch, power electronic converters capable of both MPPT and power regulation are employed in conjunction with TEGs [13]. Accordingly, a boost converter with an MPPT algorithm is widely adopted in the literature to operate TEGs at their maximum power point [14,15].
The electrical output of a TEG is typically insufficient to directly supply loads or interface with DC buses used in modern power electronic systems. Therefore, high-gain DC–DC converters are required to boost the low TEG voltage to usable levels while maintaining high efficiency, reduced current stress, and stable operation, particularly in renewable and waste-heat energy-harvesting applications. Existing studies addressing high-gain conversion for TEG systems reveal several limitations that can be broadly categorized into topological constraints, control-related shortcomings, and practical engineering limitations. From a topological perspective, various high-gain converter structures have been proposed in the literature. For instance, a high-gain boost converter was proposed for battery charging applications in [16]. Despite its voltage gain capability, the tapped-inductor configuration suffers from increased switch stress, leakage inductance effects, and diode-related losses at high-voltage levels while also lacking integrated MPPT capability for optimal power extraction from TEGs. The study mainly focuses on converter topology and loss analysis under fixed operating conditions without incorporating an advanced control strategy, which may limit its applicability in practical implementations. A reed-switch-based DC–DC converter is investigated for low-voltage TEG applications in [17]. Although the approach enables self-starting operation under very low input voltages, the use of mechanical switching elements limits switching frequency, long-term reliability, and scalability, which restricts its applicability in regulated high-voltage power electronic systems. This limitation makes the converter unsuitable for MPPT-based optimal power extraction.
The multiphase multilevel switched-capacitor converter is proposed for high-current and high-gain TEG applications [18]. The converter achieves high efficiency through ZCS operation and interleaving. However, the large number of switching devices, distributed capacitor banks, and complex control coordination increase circuit complexity and reduce voltage regulation flexibility, thereby limiting its applicability in dynamically regulated TEG systems. The switched-inductor boost regulator reported in [19] introduces a voltage-to-time-based regulation mechanism to control the output voltage of TEG-powered systems. Although the converter provides improved regulation capability for low-power integrated applications, its architecture exhibits limited scalability and voltage gain flexibility, which constrains its suitability for higher-power TEG energy-harvesting interfaces. The multilevel DC-DC conversion structure is proposed for automotive thermoelectric systems [20]. This structure improves system-level energy management by distributing multiple conversion stages. Nevertheless, the cascaded multi-stage architecture significantly increases system complexity, accumulated conversion losses, and implementation difficulty, which may limit practical deployment in compact energy-harvesting applications. In [21], a modified flyback converter with partial energy processing is analyzed to improve overall efficiency by allowing a portion of the input power to be directly delivered to the load while the remaining power is processed by the converter. Although the topology reduces component stress and improves efficiency, its performance strongly depends on converter gain and system conditions, which introduces design complexity and limits its applicability in flexible high-gain TEG interfaces.
Beyond converter topology, several studies have focused on improving the control strategies of TEG-based energy-harvesting systems. For instance, an improved fast terminal sliding mode control (FTSMC) strategy is proposed in [22] to enhance the MPPT performance of TEG arrays under dynamic temperature and load conditions. Although the approach improves tracking speed and robustness compared with conventional MPPT techniques, the inherent switching behavior of SMC may introduce chattering and control complexity, which can affect system stability and implementation in practical power electronic converters.
Considering the aforementioned TEG-supplied high-gain DC–DC converter topologies, existing multilevel structures commonly suffer from the absence of integrated MPPT capability, along with increased control complexity and cost. Moreover, conventional boost-based structures provide limited voltage gain and lack galvanic isolation between the input and output, which raises safety and system-integration concerns in high-voltage applications. The majority of existing studies lack comprehensive analysis of system performance under dynamic operating conditions and detailed descriptions of control methodologies, thereby limiting their applicability to high-voltage waste-heat energy-harvesting applications. The novelty of this study lies in the development of a modified high-gain Z-source converter structure integrated with an advanced MPC strategy for TEG-supplied high-voltage applications, addressing the shortcomings of existing studies. The proposed topology replaces the reverse-blocking diode with a synchronous MOSFET to suppress diode reverse-recovery effects, thereby improving conversion efficiency and reducing conduction losses, particularly in practical implementations. The proposed converter operates at a relatively low duty ratio (d = 0.2), while the required voltage gain can be flexibly increased through the coupled-inductor turns ratio. This approach avoids extreme duty-cycle operation, which would otherwise increase semiconductor stress and degrade transient performance.
From a control perspective, the modified Z-source converter constitutes a higher-order nonlinear system due to the interaction of multiple energy-storage elements and the coupled-inductor impedance network. Particularly in DC microgrid applications, where multiple distributed energy sources and nonlinear power electronic converters interact, advanced nonlinear control methods have attracted significant attention in recent studies [23,24]. Under such conditions, nonlinear control methods such as SMC and MPC provide improved dynamic regulation compared with conventional linear controllers. However, conventional SMC may cause voltage deviations under source variations, while conventional MPC with a fixed weighting factor may result in switching frequency variations that reduce efficiency in low-power TEG systems. Therefore, an advanced MPC strategy with an adaptive ripple-based weighting mechanism is adopted to achieve near fixed-frequency operation and improved dynamic stability.
Accordingly, a two-stage TEG-supplied architecture is developed in this study, consisting of a P&O-based MPPT boost converter followed by the proposed modified Z-source converter regulated through the advanced MPC strategy. The proposed controller is systematically compared with conventional MPC and SMC methods under multiple test scenarios. Simulation results obtained from various disturbance conditions, including temperature-dependent source variations, load perturbations, coupling-factor variations, and measurement noise, demonstrate that the proposed approach maintains stable regulation of a 400 V DC bus at a nominal switching frequency of 50 kHz, confirming its suitability for low-power TEG-based DC microgrid applications.
The remainder of this paper is organized as follows. Section 2 introduces the operating principle and electrical modeling of thermoelectric generators. Section 3 presents the proposed two-stage TEG-supplied power conversion system. Section 4 describes the simulation results and performance evaluation. Section 5 provides a summary and comparative analysis. Finally, Section 6 concludes the paper.
2. Operating Principle of Thermoelectric Generators
A basic structure of a TEG is composed of p-type and n-type legs between a hot and a cold surface, where the temperature gradient drives charge carrier flow to generate electrical power across the load, as shown in Figure 1. Multiple p–n pairs, commonly referred to as thermoelectric (TE) couples, are electrically connected and inserted between two ceramic plates to form a TEG.
Figure 1.
Basic structure of a thermoelectric generator.
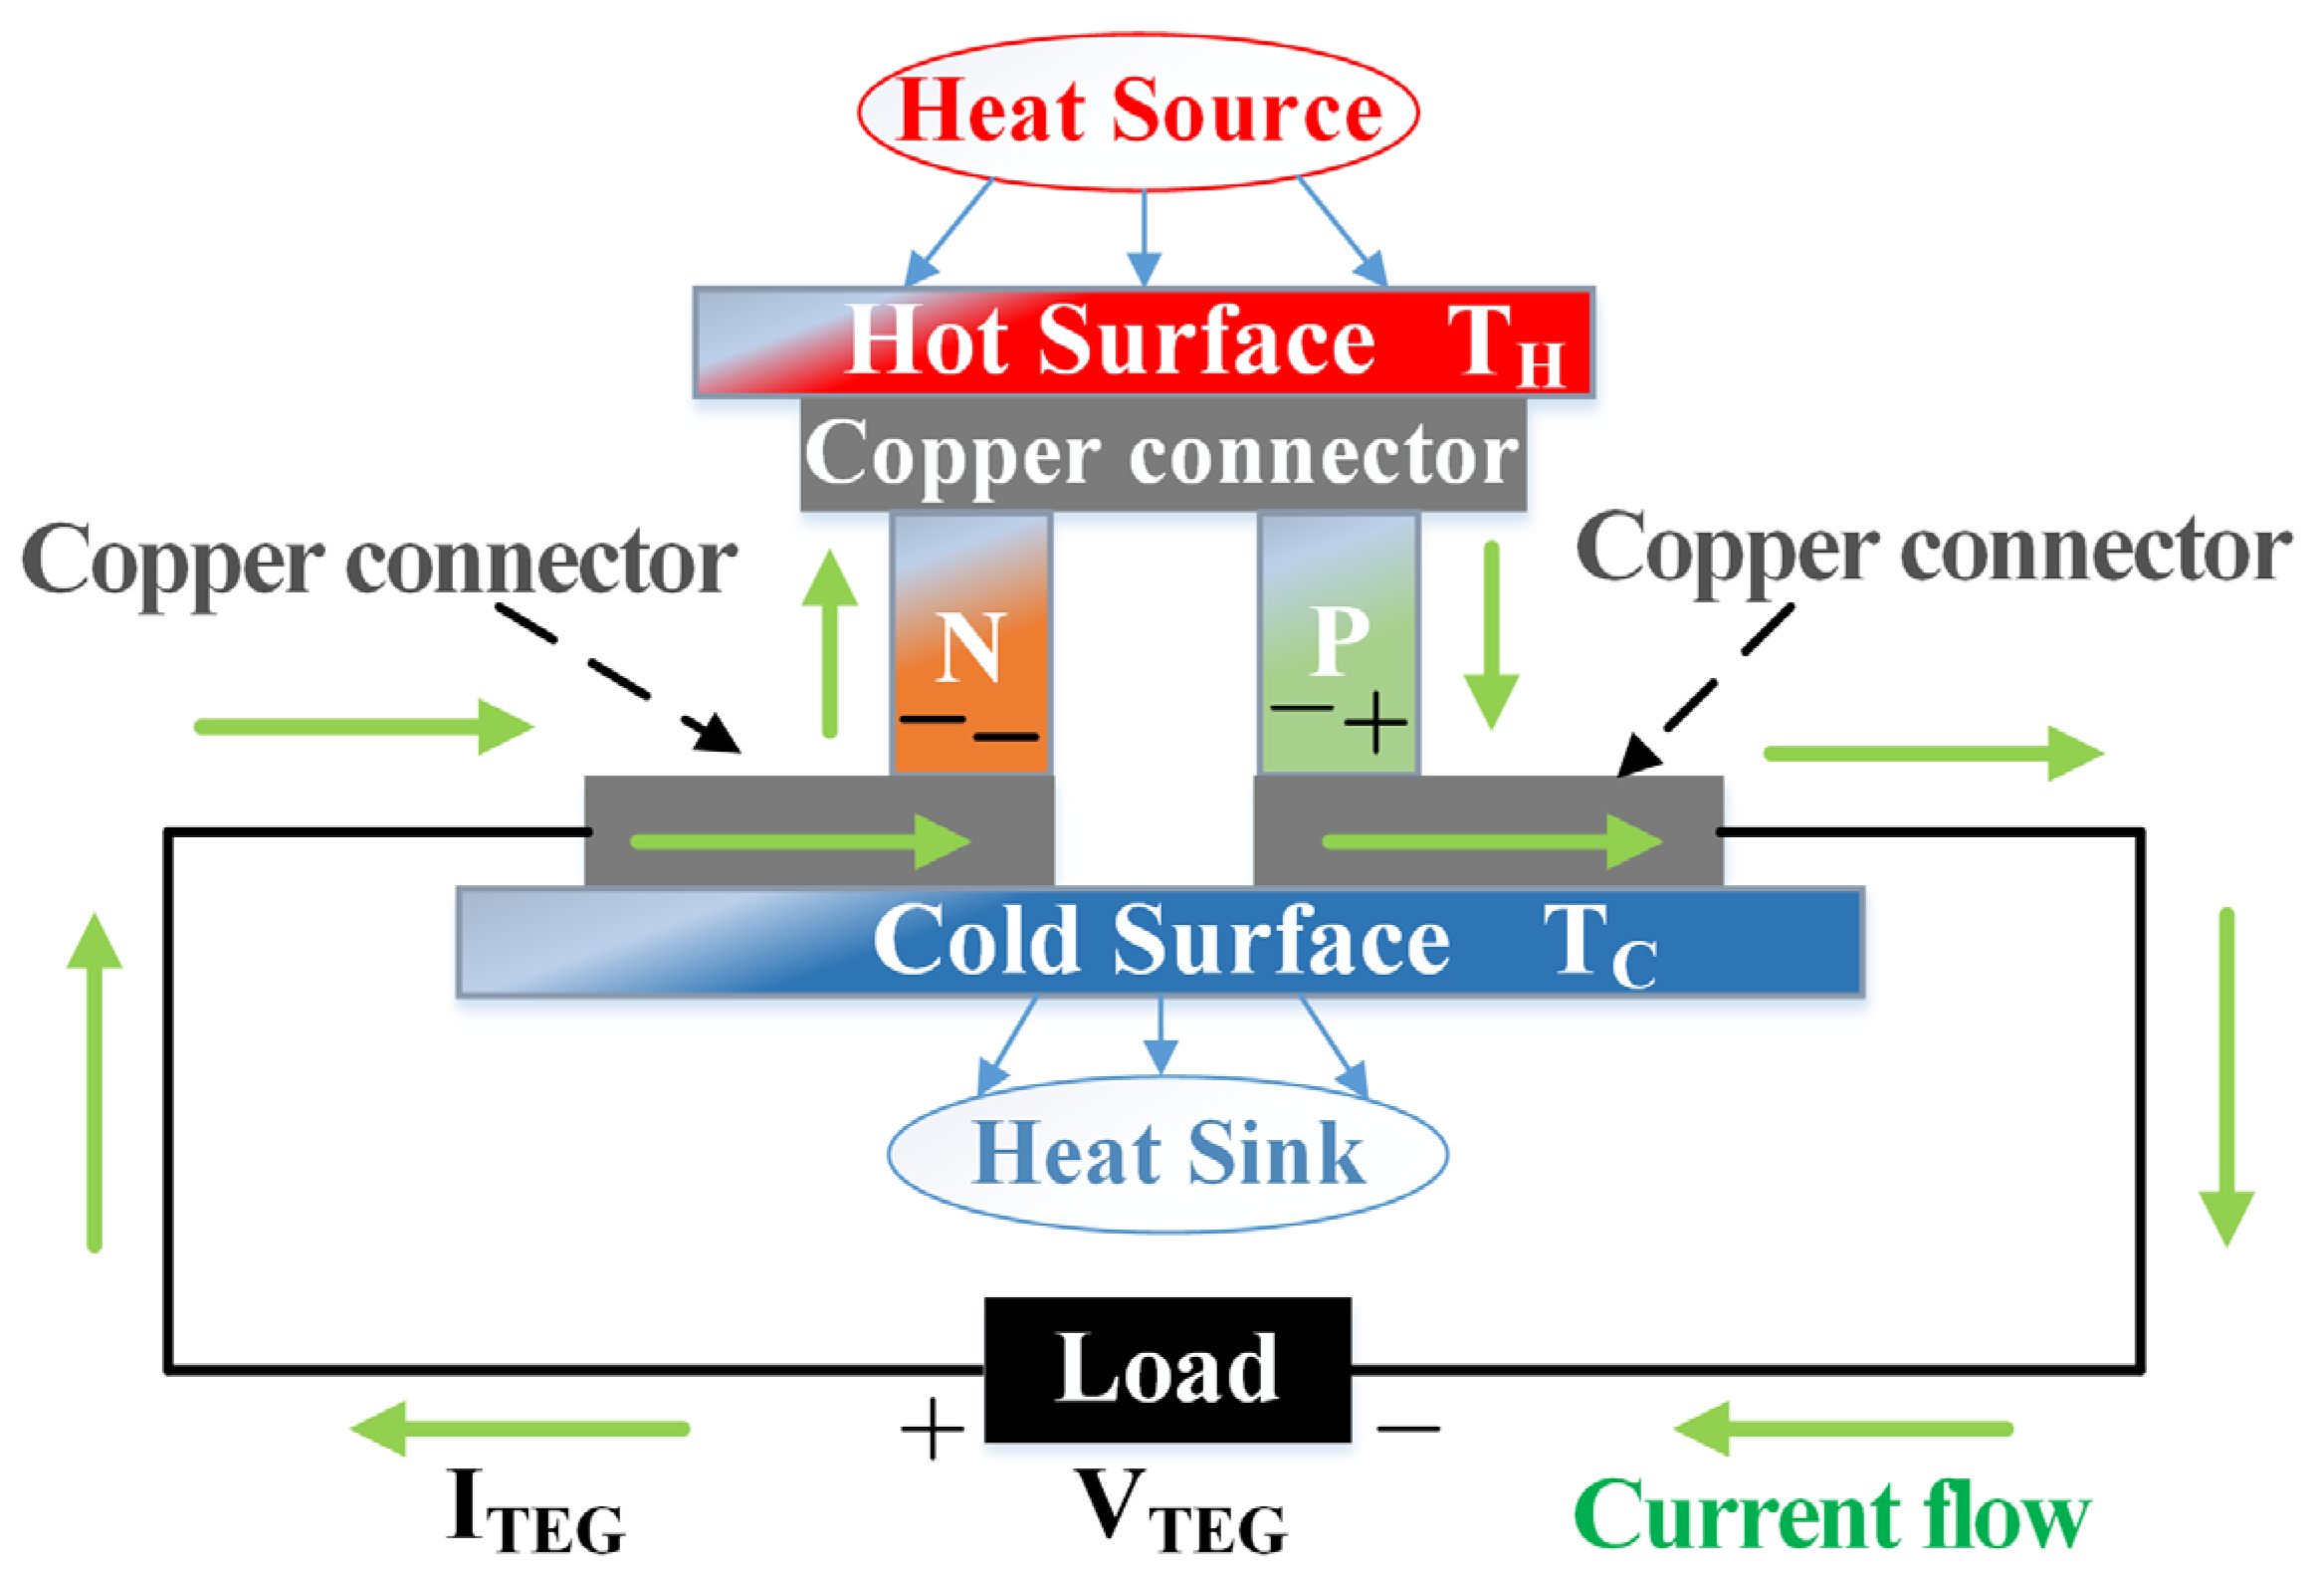
TEG modules fabricated from thermoelectric materials generate an output voltage proportional to the temperature difference across the module [25]. TEs in a TEGs are electrically connected in series to increase the output voltage, while they are thermally arranged in parallel through ceramic plates to enhance thermal conductivity. When a temperature difference is established between the ceramic plates, heat flows from the hot side to the cold side, inducing the movement of electrons and holes in the n-type and p-type semiconductors, which generates an electrical voltage via the Seebeck effect. The open-circuit voltage of the TE is given by the following expression:
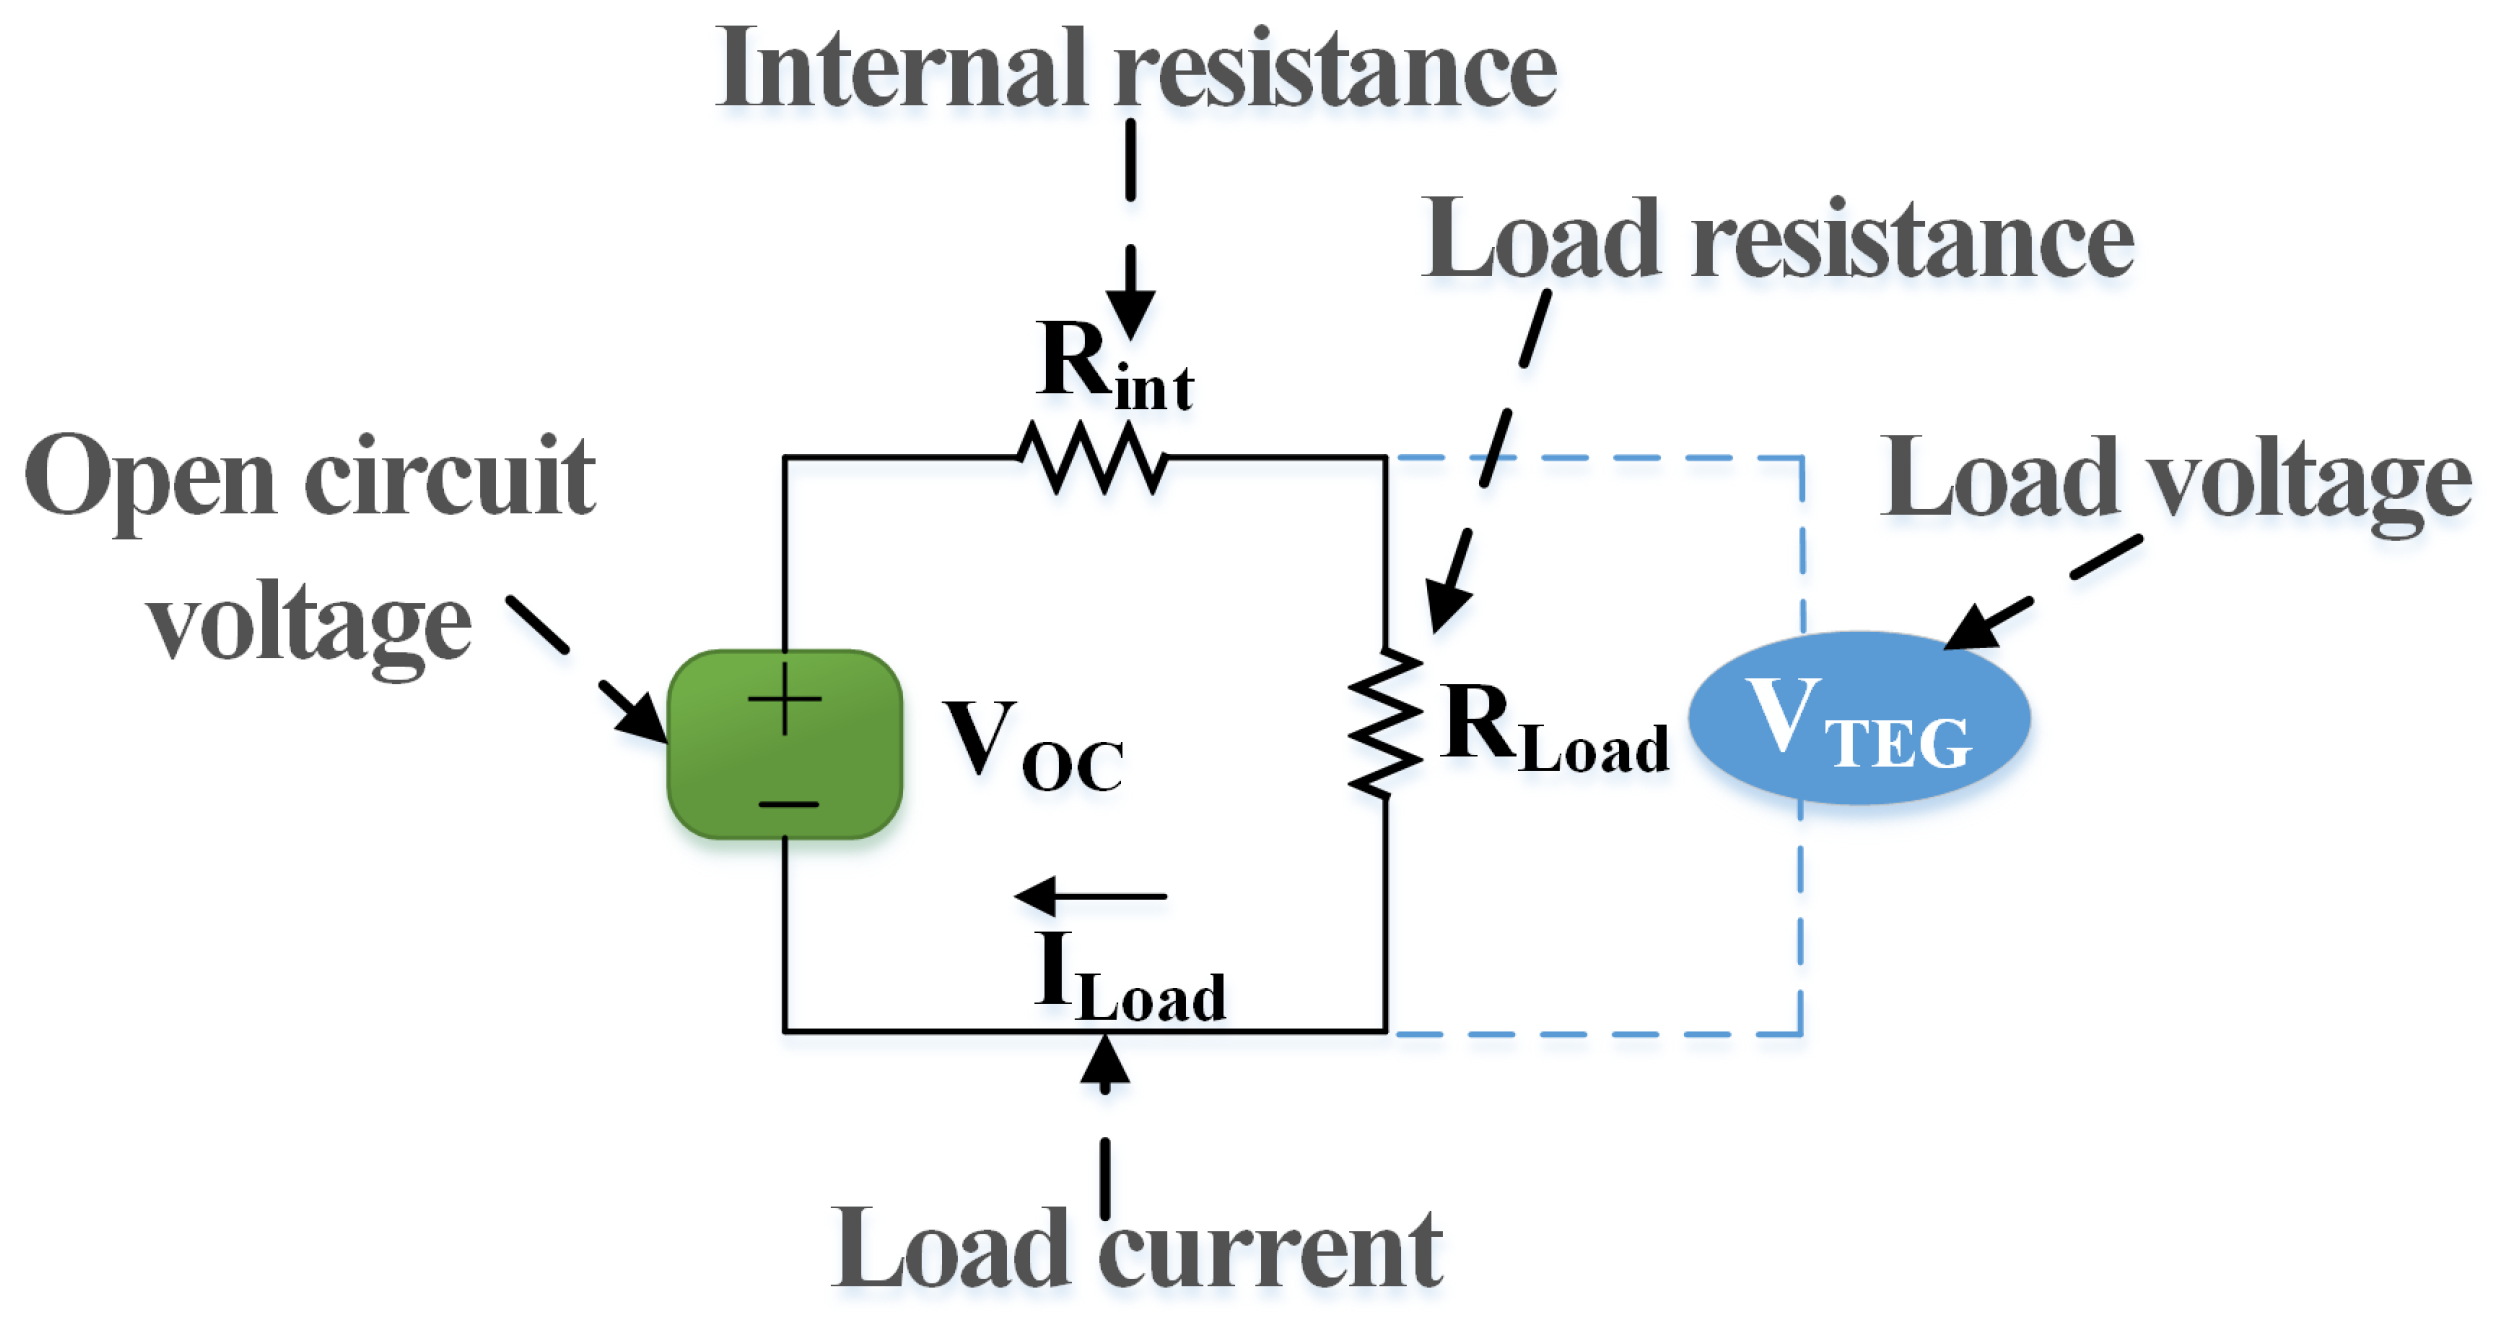
where denotes the open-circuit voltage of the TEG, represents the Seebeck coefficient (V/K), and is the temperature difference between the hot and cold surfaces of the TEG (K). From an electrical standpoint, a TEG can be modeled as a temperature-dependent voltage source in series with an internal resistance, . A load resistance, , is connected to the TEG to extract electrical power. When the load resistance matches the internal resistance of the TEG, the power delivered to the load reaches its maximum value, known as the MPP. Deviations from this condition result in a reduction in the extracted power. Under open-circuit conditions (), the TEG terminals exhibit the open-circuit voltage, whereas under short-circuit conditions (), the short-circuit current flows through the TEG. At the MPP condition, the TEG terminal voltage and output current are equal to half of the open-circuit voltage and short-circuit current, respectively, as formulated below:
where and correspond to the voltage (V) and current (A) at which the TEG delivers maximum power, respectively, while denotes the short-circuit current (A) of the device.
The electrical equivalent circuit model of the TEG is represented in Figure 2. Based on Kirchhoff’s laws, the TEG current can be formulated as follows:
The terminal voltage of the TEG denotes the output voltage available at the terminals when supplying a load and is given by:
Under open-circuit conditions, no current flows through the TEG, and the terminal voltage equals the open-circuit voltage, as given by:
Under short-circuit conditions, the terminal voltage drops to zero and the current reaches its maximum value, known as the short-circuit current, as given by:
The electrical power generated by a TEG module is delivered to a load and can be expressed in terms of the TEG voltage, its internal resistance and the load resistance as follows:
Figure 2.
The electrical equivalent circuit model of the TEG.
The electrical output of TEGs is directly dependent on the temperature difference across the device; however, TEGs typically operate under nonlinear temperature gradient conditions due to varying thermal profiles. Variations in temperature affect not only the output power of TEGs but also their internal resistance [13] and Seebeck coefficient [26].
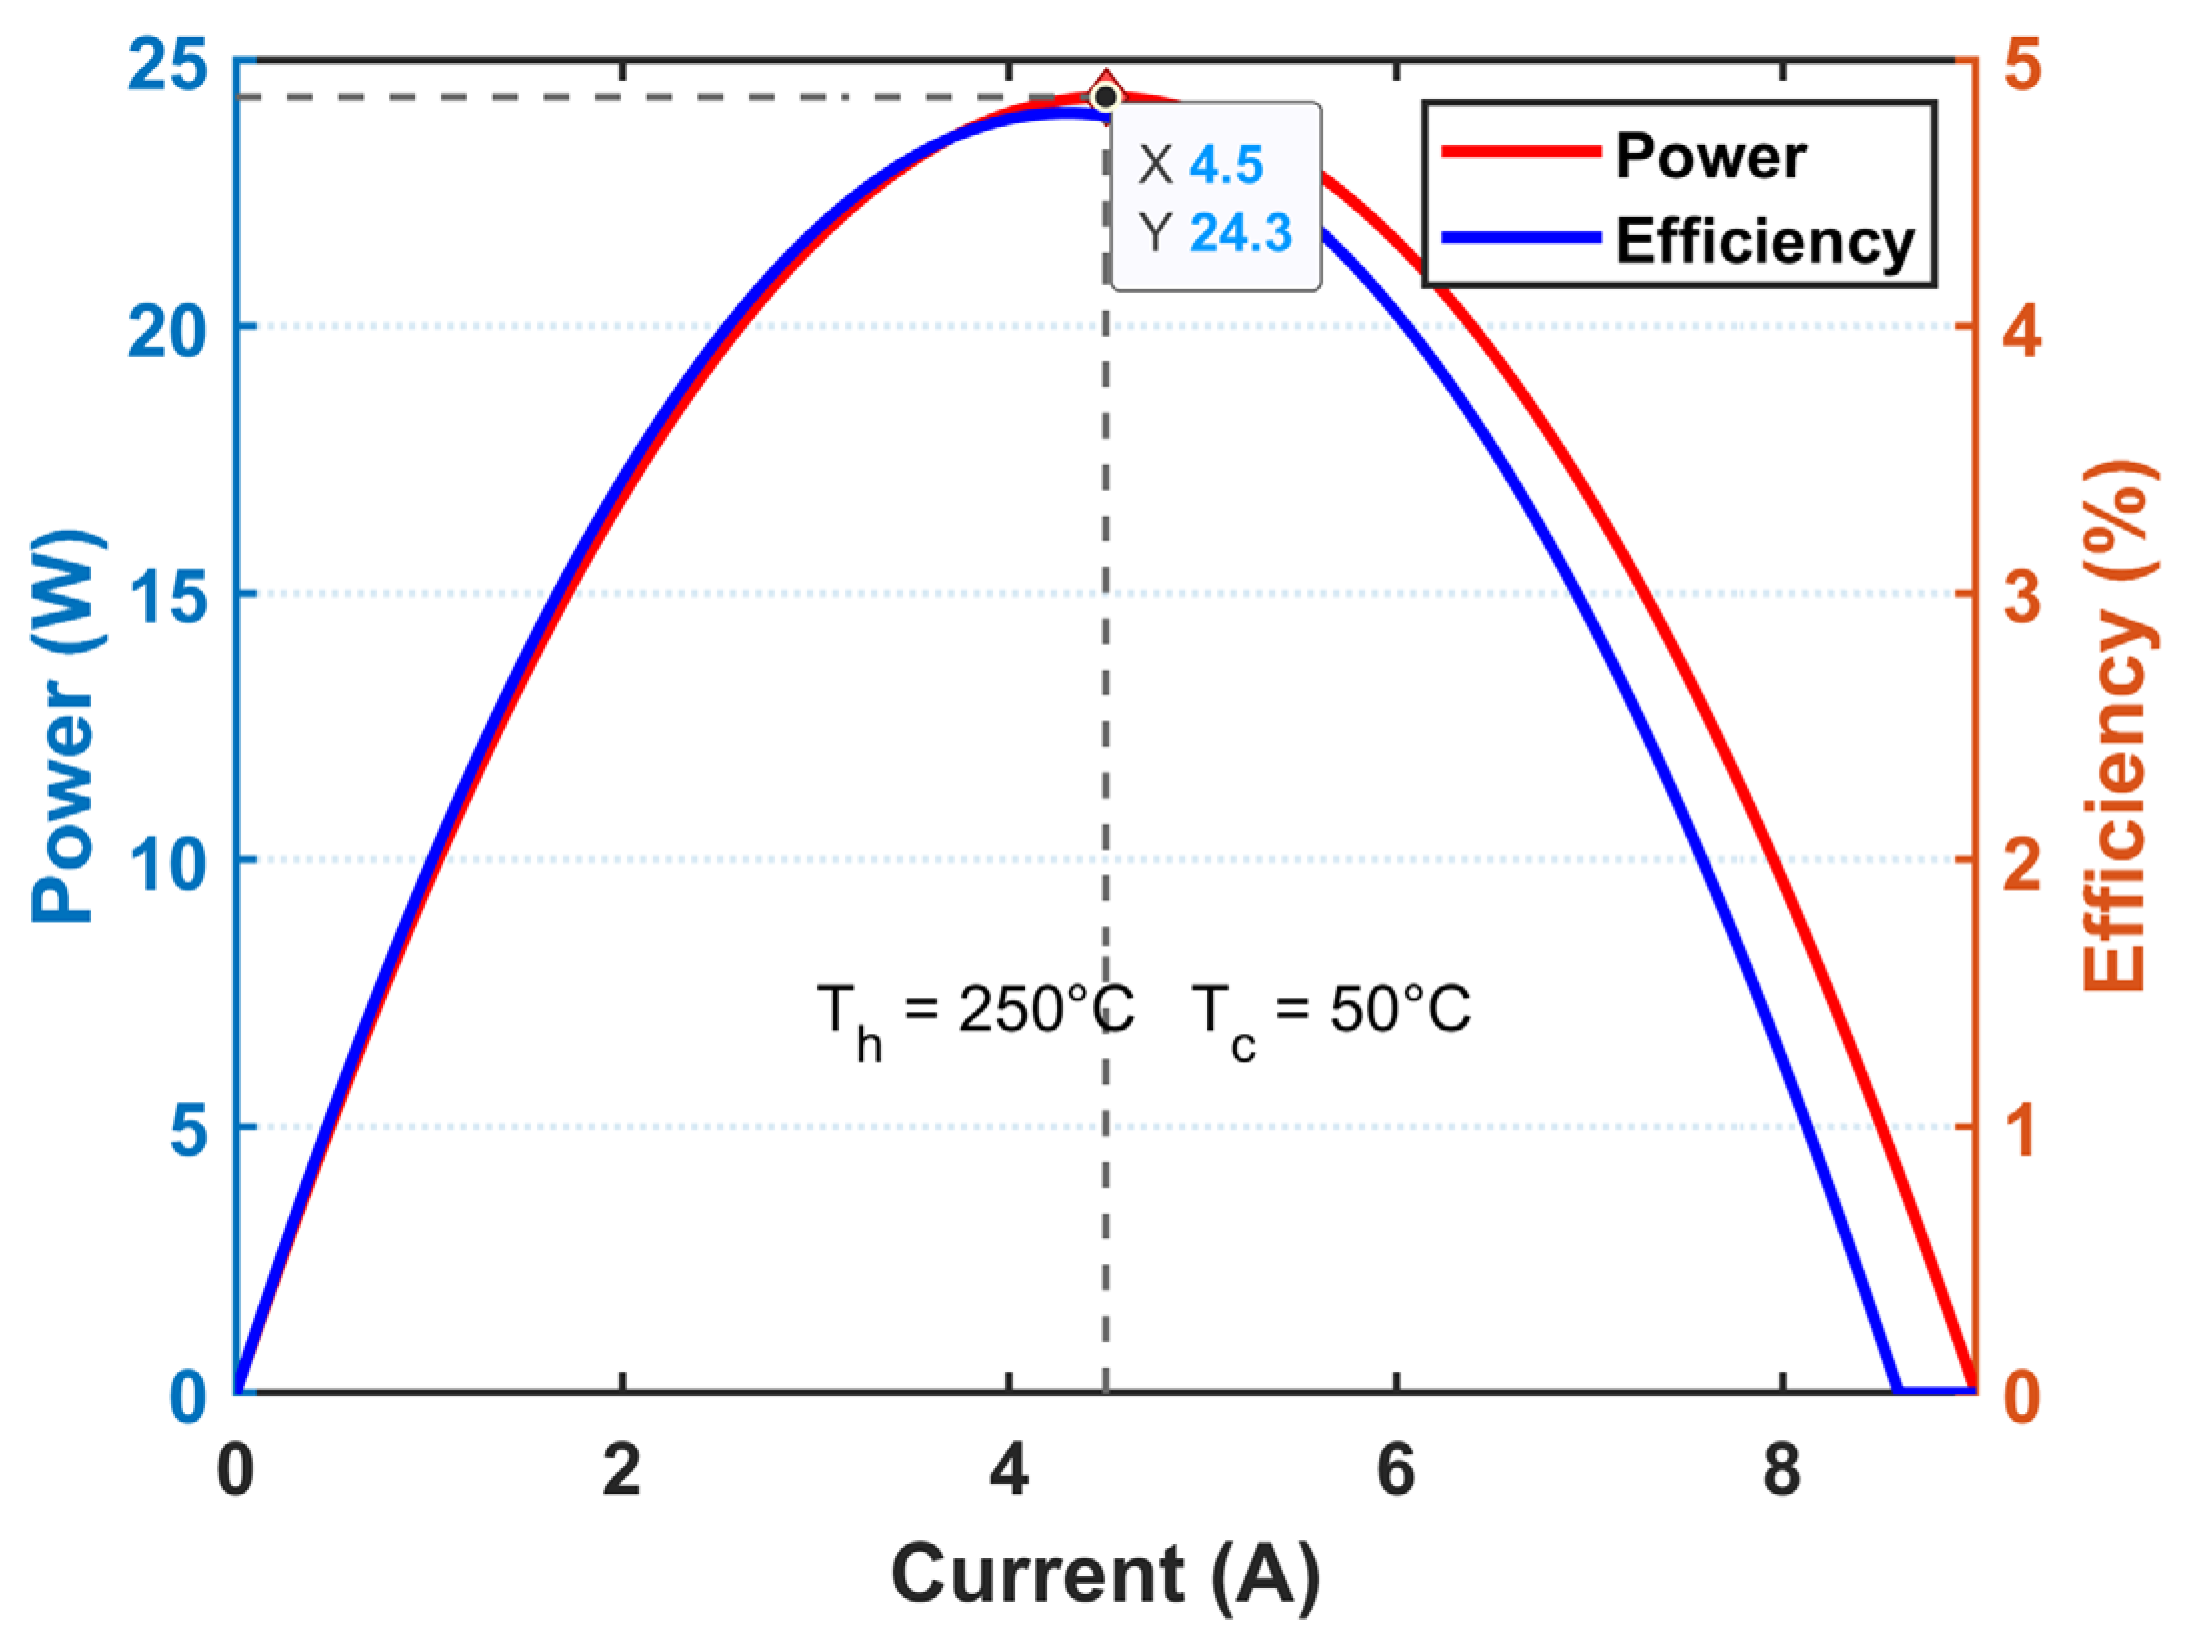
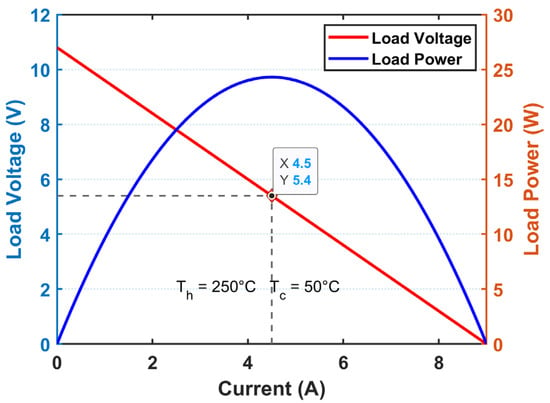
This study employs manufacturer datasheet parameters of the HZ-20HV module manufactured by Hi-Z Technology to model a TEG system. Figure 3 illustrates the power and efficiency characteristics of the designed system, while Figure 4 depicts the corresponding load curve. A TEG system composed of five modules connected in series is implemented in MATLAB/Simulink R2023b based on these specifications. The electrical and thermal characteristics of the TEG are summarized in Table 1 in the following section.
Figure 3.
Power and efficiency characteristics of the designed TEG module.
Figure 4.
I-V and P-V curve of the designed TEG module.
Table 1.
Parameter specifications of the proposed system.
3. The Proposed Two-Stage TEG-Supplied System
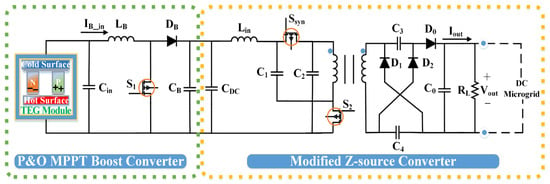
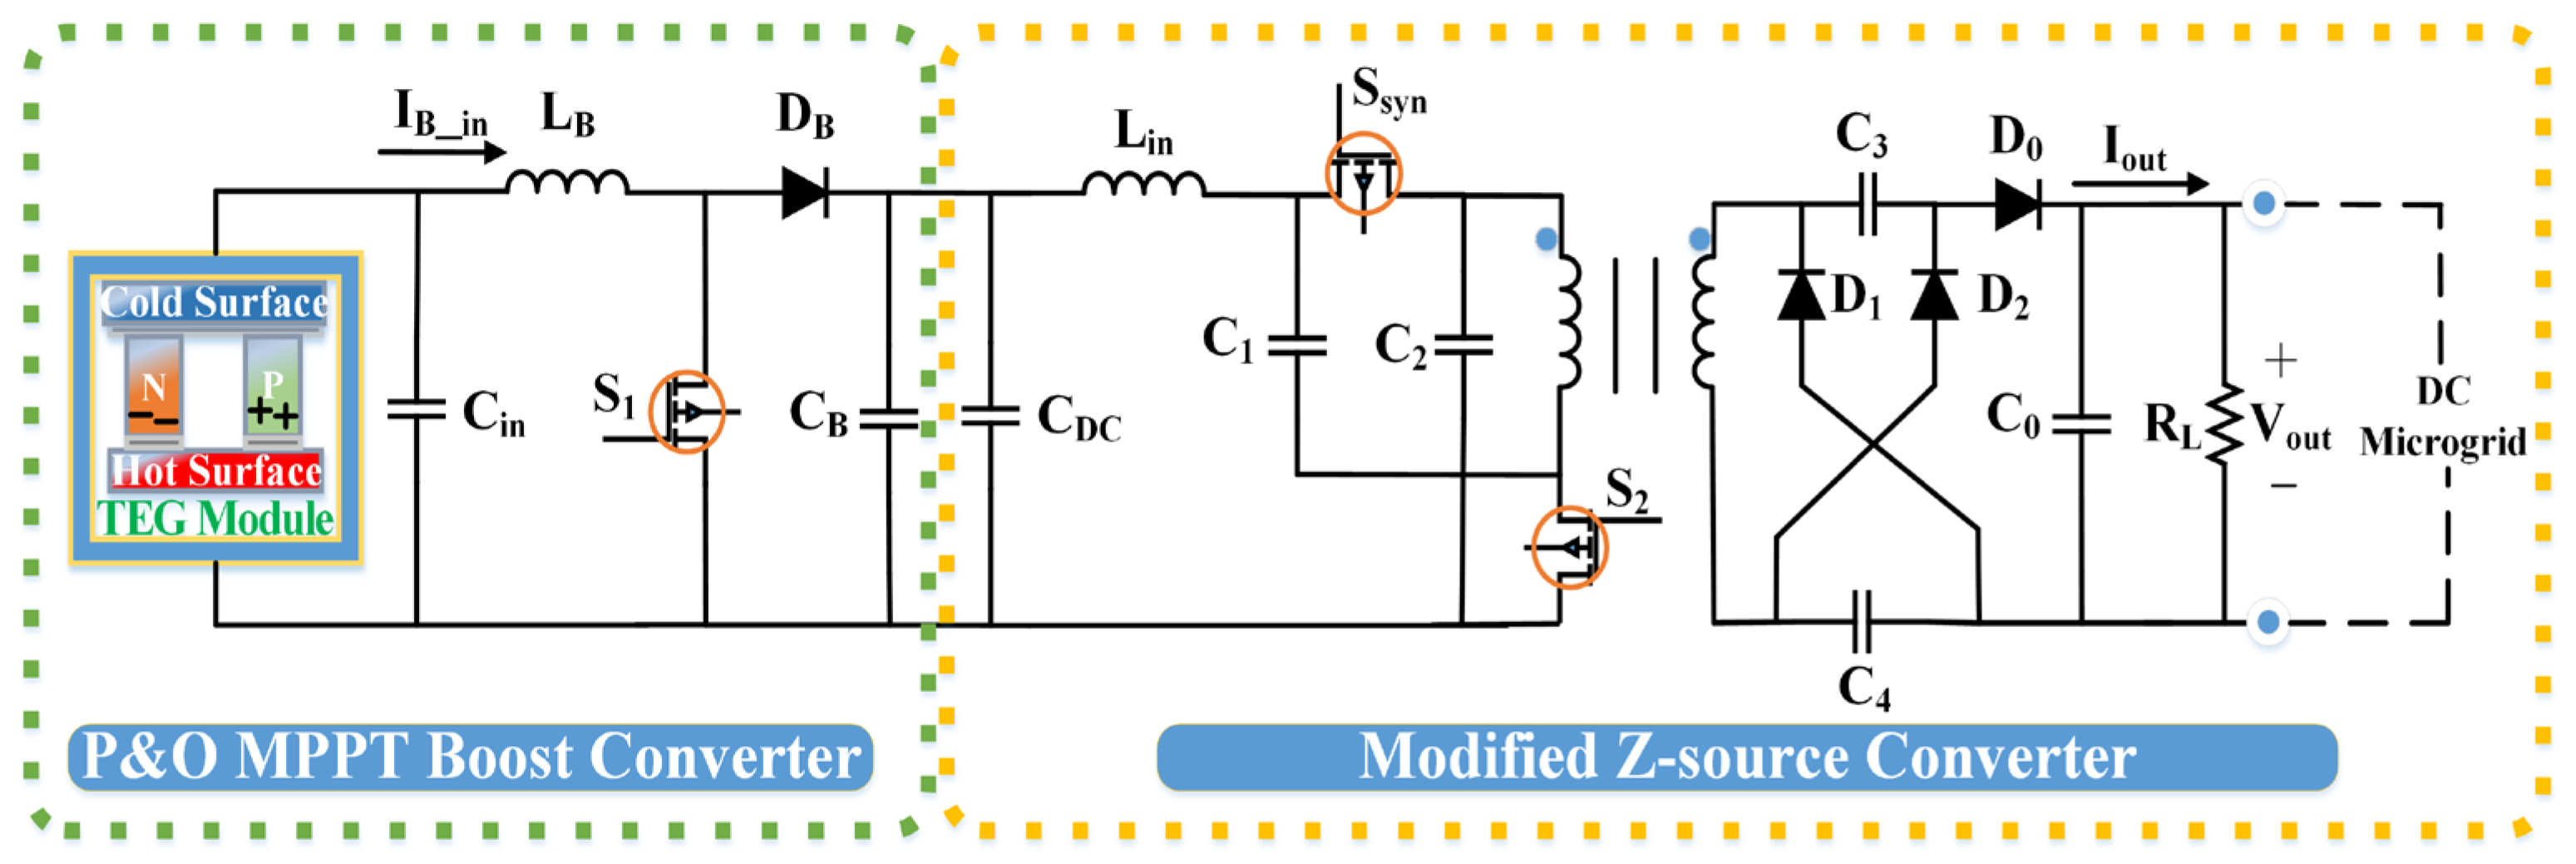
This section introduces the proposed TEG-supplied system for low-power DC microgrid applications, as depicted in Figure 5. The proposed system can be classified as a two-stage architecture. The first stage incorporates a P&O-based MPPT boost converter to step up the TEG voltage and regulate the output current. In the second stage, a modified Z-source converter with an advanced model predictive control method is employed to boost the voltage to 400 V, which is a widely recognized DC bus level in low-power DC microgrids due to its reduced distribution losses, compatibility with power electronic interfaces, and direct integration with battery storage and EV charging systems. Herein, the integrated advanced MPC method is compared with conventional MPC and conventional SMC to demonstrate its superiority for the considered application. The design and operation of the first-stage MPPT boost converter, along with the detailed behavior of the second-stage modified Z-source converter and its associated control strategies, are presented in the following subsections.
Figure 5.
The proposed TEG-supplied system.
3.1. First-Stage Boost Converter: Design and MPPT Implementation
MPPT is a widely adopted control strategy that enables power systems to operate at their maximum power point under varying operating conditions. In TEG systems, the implementation of MPPT algorithms is particularly critical due to the inherently low conversion efficiency of TEGs. Based on the MPPT theorem [27], maximum power is obtained from a TEG when the load resistance equals its internal resistance, and this condition varies as the internal resistance of the TEG changes. Since the thermal energy input in waste-heat recovery systems is essentially cost-free, the inherently low conversion efficiency of thermoelectric generators is not a primary concern; instead, maximizing the extracted electrical power through MPPT becomes crucial to minimize the cost per watt of generated energy. MPPT algorithms are implemented in conjunction with DC–DC converters to achieve impedance matching between the TEG and the load, thereby ensuring continuous operation of the TEG at its MPP. The power transferred to the load depends on the load resistance; thus, MPPT implementation via a DC–DC converter must account for the load-dependent I–V and P–V characteristics of the TEG system to ensure operation at the MPP.
In this study, a duty-cycle-based P&O MPPT algorithm is used to achieve load matching, and the flowchart of the algorithm is shown in Figure 6. The P&O method is preferred due to its simple structure, low computational burden, model-free implementation, and inherent robustness against parameter variations and measurement noise, making it well suited for low-power TEG applications. The P&O MPPT algorithm tracks the MPP by iteratively perturbing the converter duty-cycle and observing the resulting power variation. Herein, the algorithm evaluates the signs of the power and voltage changes to determine the appropriate direction of duty-cycle adjustment, thereby driving the operating point toward the MPP. The P&O MPPT algorithm is particularly suitable for TEG applications due to its simple structure, low computational burden, model-free nature, and ease of implementation with DC–DC converters, making it robust against parameter variations inherent in TEG systems.
Figure 6.
Flowchart of the duty-cycle-based perturb-and-observe (P&O) MPPT algorithm.
DC–DC converters are power electronic systems that efficiently regulate and convert DC voltage levels to interface energy sources with electrical loads. TEG arrays are used to supply the boost converter to increase the input voltage. The conventional boost converter mainly consists of an inductance , an MOSFET used as a switch, a diode , and a capacitor . The primary function of the converter is to achieve impedance matching between the TEG and the load by adjusting the switch duty-cycle, thereby enabling maximum power extraction. The circuit schematic is employed to model and analyze the converter behavior during the MOSFET On and Off switching intervals and to derive the associated circuit equations. When the MOSFET is in the ON state, the diode becomes reverse-biased, and the TEG supplies energy to the inductor, causing the inductor current to increase and store energy in its magnetic field. During this interval, the output capacitor supplies the load by discharging, thereby maintaining the output voltage. Conversely, when the MOSFET is turned OFF, the stored energy in the inductor is transferred through the diode to the output capacitor and the load, resulting in a stepped-up output voltage. Utilizing Faraday’s Law, the rate of change for the state variables across both operational intervals is formulated as [22,28]:
Due to the low-output voltage nature of the TEG, the use of a boost converter is suitable for high-voltage applications. denotes the internal resistance of the TEG, and is the load of the circuit. The boost converter is capable of stepping up the input DC voltage to a desired higher level by appropriately controlling the switching duty-cycle. The steady-state voltage conversion ratio of the boost converter is expressed as:
The steady-state current conversion ratio of the boost converter is expressed as:
The steady-state input impedance seen by the TEG through the boost converter is related to the load resistance as follows:
Based on the minimum and maximum TEG voltage, the min and max duty–cycle ratio can be determined as follows:
In selecting the inductor value, continuous conduction mode (CCM) operation is maintained by ensuring . The minimum inductance, is defined as follows:
To ensure voltage stability at the output, the minimum DC-link capacitance is obtained as follows:
Based on the aforementioned operating principle, the design parameters of the TEG-supplied boost converter are presented in Table 1.
3.2. Second-Stage Modified Z-Source Converter Topology
Continuous input current and high step-up conversion capability are essential requirements for DC–DC converters interfacing renewable energy sources such as photovoltaic panels, fuel cells, and thermoelectric generators (TEGs), since these sources inherently operate at low-voltage levels and exhibit significant source impedance. In such scenarios, isolated topologies, including flyback converters, suffer from high switching stress, bulky magnetic components, and reduced power density, which limit their suitability for compact and low-power TEG-assisted power-conditioning systems.
To achieve high-voltage gain for DC microgrid interfacing without extreme duty-cycle operation, impedance-source converter structures provide a more appropriate alternative due to their inherent boost capability, reduced semiconductor stress, and transformerless operation. Accordingly, a modified Z-source converter is employed in the second stage to elevate the regulated DC-link voltage to the 400 V DC bus level while maintaining a compact structure and improved efficiency.
Impedance-source converters can be classified into three groups based on the switching stage configuration: full-bridge [29], push–pull [30], and single-switch topologies [31]. Among these, single-switch configurations offer reduced semiconductor count, simplified gate-drive circuitry, lower switching losses, and continuous input current characteristics, making them particularly suitable for low-voltage energy-harvesting applications such as TEG systems. Their reduced circuit complexity and wide boost-conversion capability enable compact, cost-effective, and efficient implementations at low-power levels.
In this study, a prominent single-switch Z-source converter structure is adapted for MPPT-enabled low-power TEG systems, owing to its compact structure and reduced circuit complexity [32]. The modified structure primarily consists of replacing the reverse-blocking diode with a synchronous MOSFET, as depicted in Figure 5. This replacement eliminates reverse-recovery losses and improves conversion efficiency, especially in practical applications. The improvement is particularly relevant for TEG-assisted applications, since diode reverse-recovery losses become significant at low current levels and high switching frequencies. The operating modes and steady-state characteristics of the proposed topology are presented in the following subsection.
3.2.1. Topology Description and Operating Modes
The proposed second-stage modified Z-source converter employed in this study is illustrated in Figure 5. The topology is designed to provide high-voltage gain while preserving continuous input current characteristics and reduced semiconductor stress, which are essential for low-power TEG applications. The proposed circuit consists of five capacitors (, , , and ), three diodes (, and ), an input inductor , and a coupled-inductor structure formed by primary and secondary windings and . The impedance network of the proposed topology is formed by capacitors and , which establish the primary voltage-boosting mechanism together with the coupled-inductor structure. Capacitors and are located on the secondary side and participate in the intermediate energy transfer process, contributing to the enhanced voltage gain and shaping the energy flow toward the output stage. The output section consists of diode , the output capacitor , and the load , where maintains the regulated 400 V DC output voltage supplied to the microgrid interface. While is the main switch, represents the synchronous switch.
Unlike conventional single-switch Z-source configurations, the proposed modification replaces the reverse-blocking diode with the synchronous MOSFET . This modification aims to eliminate reverse-recovery effects and reduce conduction losses, which are particularly critical in low-power TEG-assisted systems operating at high switching frequencies. The synchronous implementation improves overall conversion efficiency while maintaining the structural simplicity of the single-switch impedance-source architecture.
The operation of the converter can be described in two fundamental switching intervals determined by the state of the main switch .
Mode I (Main Switch ON State):
When the main switch is turned ON, the synchronous switch remains OFF. During this interval, the input inductor stores energy from the regulated DC-link supplied by the first-stage boost converter. The impedance network establishes the energy transfer mechanism toward the secondary side of the coupled-inductor. The output stage is supported by the discharge of the intermediate capacitors, while the output capacitor maintains the DC bus voltage supplied to the load. The diode conduction states are determined by the instantaneous voltage polarities within the impedance network.
Mode II (Main Switch OFF State):
When the main switch is turned OFF, the synchronous switch is activated to provide a low-loss current path for the inductor currents. In this interval, the energy stored in the magnetic components is transferred through the impedance network toward the output stage. The synchronous conduction path suppresses reverse-recovery phenomena and mitigates switching-related stress, resulting in improved efficiency and smoother current transitions. The output capacitor continues to regulate the DC bus voltage supplied to the load. Through these two operating modes, the proposed modified Z-source converter achieves high step-up conversion without extreme duty-cycle operation. The topology preserves continuous input current characteristics, reduces semiconductor stress, and enhances efficiency through synchronous rectification. The steady-state characteristics and dynamic behavior of the converter are analyzed in the following subsections.
3.2.2. Steady-State Analysis of the Modified Z-Source Converter Topology
The steady-state analysis of the proposed modified Z-source converter is carried out under CCM operation. The derivation follows the classical modal analysis framework commonly employed for single-switch impedance-source converters, as reported in [32], with the primary structural difference being the replacement of the freewheeling diode by a synchronous MOSFET. Since this modification does not alter the fundamental voltage–second balance relationships of the magnetic components, the steady-state gain structure remains consistent with the reference topology.
For steady-state operation, the following assumptions are made:
- All semiconductor devices are considered ideal.
- The inductors and capacitors are sufficiently large such that their ripple components are negligible within one switching period.
- The converter operates in CCM.
When the main switch is in the ON state and the synchronous MOSFET is in the OFF state, while is forward-biased, and are reverse-biased, as described in the previous section, applying Kirchhoff’s voltage law (KVL) to the input inductor yields the following:
When the main switch is in the OFF state and the synchronous MOSFET is in the ON state, providing a low-loss path for the inductor currents, while the impedance network reconfigures for boosting as described in the previous section, the KVL of the input inductor is given as follows:
Over one switching period, volt–second balance on is obtained as:
By substituting the ON state and OFF state inductor voltage expressions given in Equations (16) and (17) into the volt–second balance condition in Equation (18), and then applying the standard impedance–network relations of the coupled-inductor, the steady-state voltage conversion ratio is obtained as follows:
where d is the duty-cycle of the switch, n is the turn ratio of the coils, and k represents the coupling-factor of the system.
Accordingly, the capacitor voltages are derived from the steady-state interval relations and the charge-balance constraints as follows:
Diode voltage relations can be represented as follows:
The main switch and synchronous switch voltage stresses are obtained directly from the steady-state capacitor relations as follows:
The steady-state current relations for the input inductor and the mutual inductor can be expressed as follows:
3.2.3. Dynamic Modeling of the Modified Z-Source Converter Topology
In order to characterize the transient behavior of the proposed modified Z-source converter and to establish a mathematical basis for the control strategies considered in this study, a control-oriented dynamic model is formulated in the time domain. Unlike the steady-state analysis presented in the previous subsection, the dynamic model describes the evolution of the dominant state variable within a switching period.
Considering the converter structure and its two switching intervals, the input inductor current is selected as the main state variable since it directly reflects the instantaneous energy exchange between the regulated DC-link, the impedance network, and the coupled-inductor stage. Accordingly, the continuous-time differential equation of can be expressed as:
where denotes the switching state of the main switch, is the regulated intermediate DC-link voltage provided by the first stage, and and represent the capacitor voltages of the impedance network.
Based on Euler’ forward method, the continuous-time derivative of can be obtained as follows:
Substituting Equation (30) into Equation (29), the one-step-ahead predictive expression of the inductor current is obtained as
Equations (29)–(31) define the continuous and discrete-time representations of the modified Z-source converter dynamics. Equation (31) represents the one-step-ahead discrete-time current update derived from the continuous model and is required for digital implementation and predictive control evaluation. While the conventional PWM-based SMC is formulated directly from the continuous-time model in Equation (29), the MPC-based controllers explicitly utilize the discrete-time prediction model in Equation (31) to evaluate candidate switching states.
3.2.4. Control Design and Comparative Analysis
Based on the steady-state characteristics presented in Section 3.2.2 and the dynamic model derived in Section 3.2.3, this subsection introduces the control strategies implemented for the modified Z-source converter and establishes a clear comparative framework. To maintain structural consistency, the mathematical modeling of the converter is confined to the previous subsection, while this part focuses exclusively on controller design and performance evaluation.
For high-gain DC–DC converters operating under nonlinear and dynamic conditions, SMC and MPC are widely adopted due to their robustness and fast response characteristics. Accordingly, conventional PWM-based SMC and conventional MPC are introduced as benchmark methods, followed by the detailed formulation of the proposed advanced MPC strategy.
Conventional PWM-based sliding mode control strategy
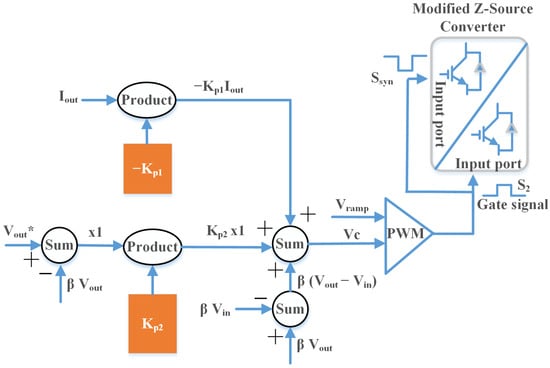
A PWM-based SMC is adopted as a conventional benchmark, as illustrated in Figure 7 [33]. The parameters , , , and denote input voltage, output voltage, reference output voltage, and output current, respectively. and are proportional gains associated with the sliding surface dynamics, and is a scaling parameter used in the auxiliary state definition. The controller forms a sliding surface from the output voltage error and its derivative, and the resulting control signal is processed through a PWM ramp comparator to yield a fixed switching frequency. In operation, the sliding function drives the output voltage toward its reference and maintains the system trajectory on the sliding surface, enabling fast transient response and small steady-state error. Although SMC offers fast transient response and inherent robustness against parameter uncertainties without requiring an explicit mathematical model, this model-free nature becomes a limitation in high-gain and high-order impedance-source converters. In such topologies, accurate prediction of converter dynamics and switching behavior is essential due to strong nonlinearities and complex impedance–network interactions. The absence of an explicit prediction mechanism may therefore result in noticeable voltage deviations under large source variations and dynamic operating conditions, as evidenced in the simulation results.
Figure 7.
Block diagram of the conventional SMC method.
Conventional model predictive control strategy
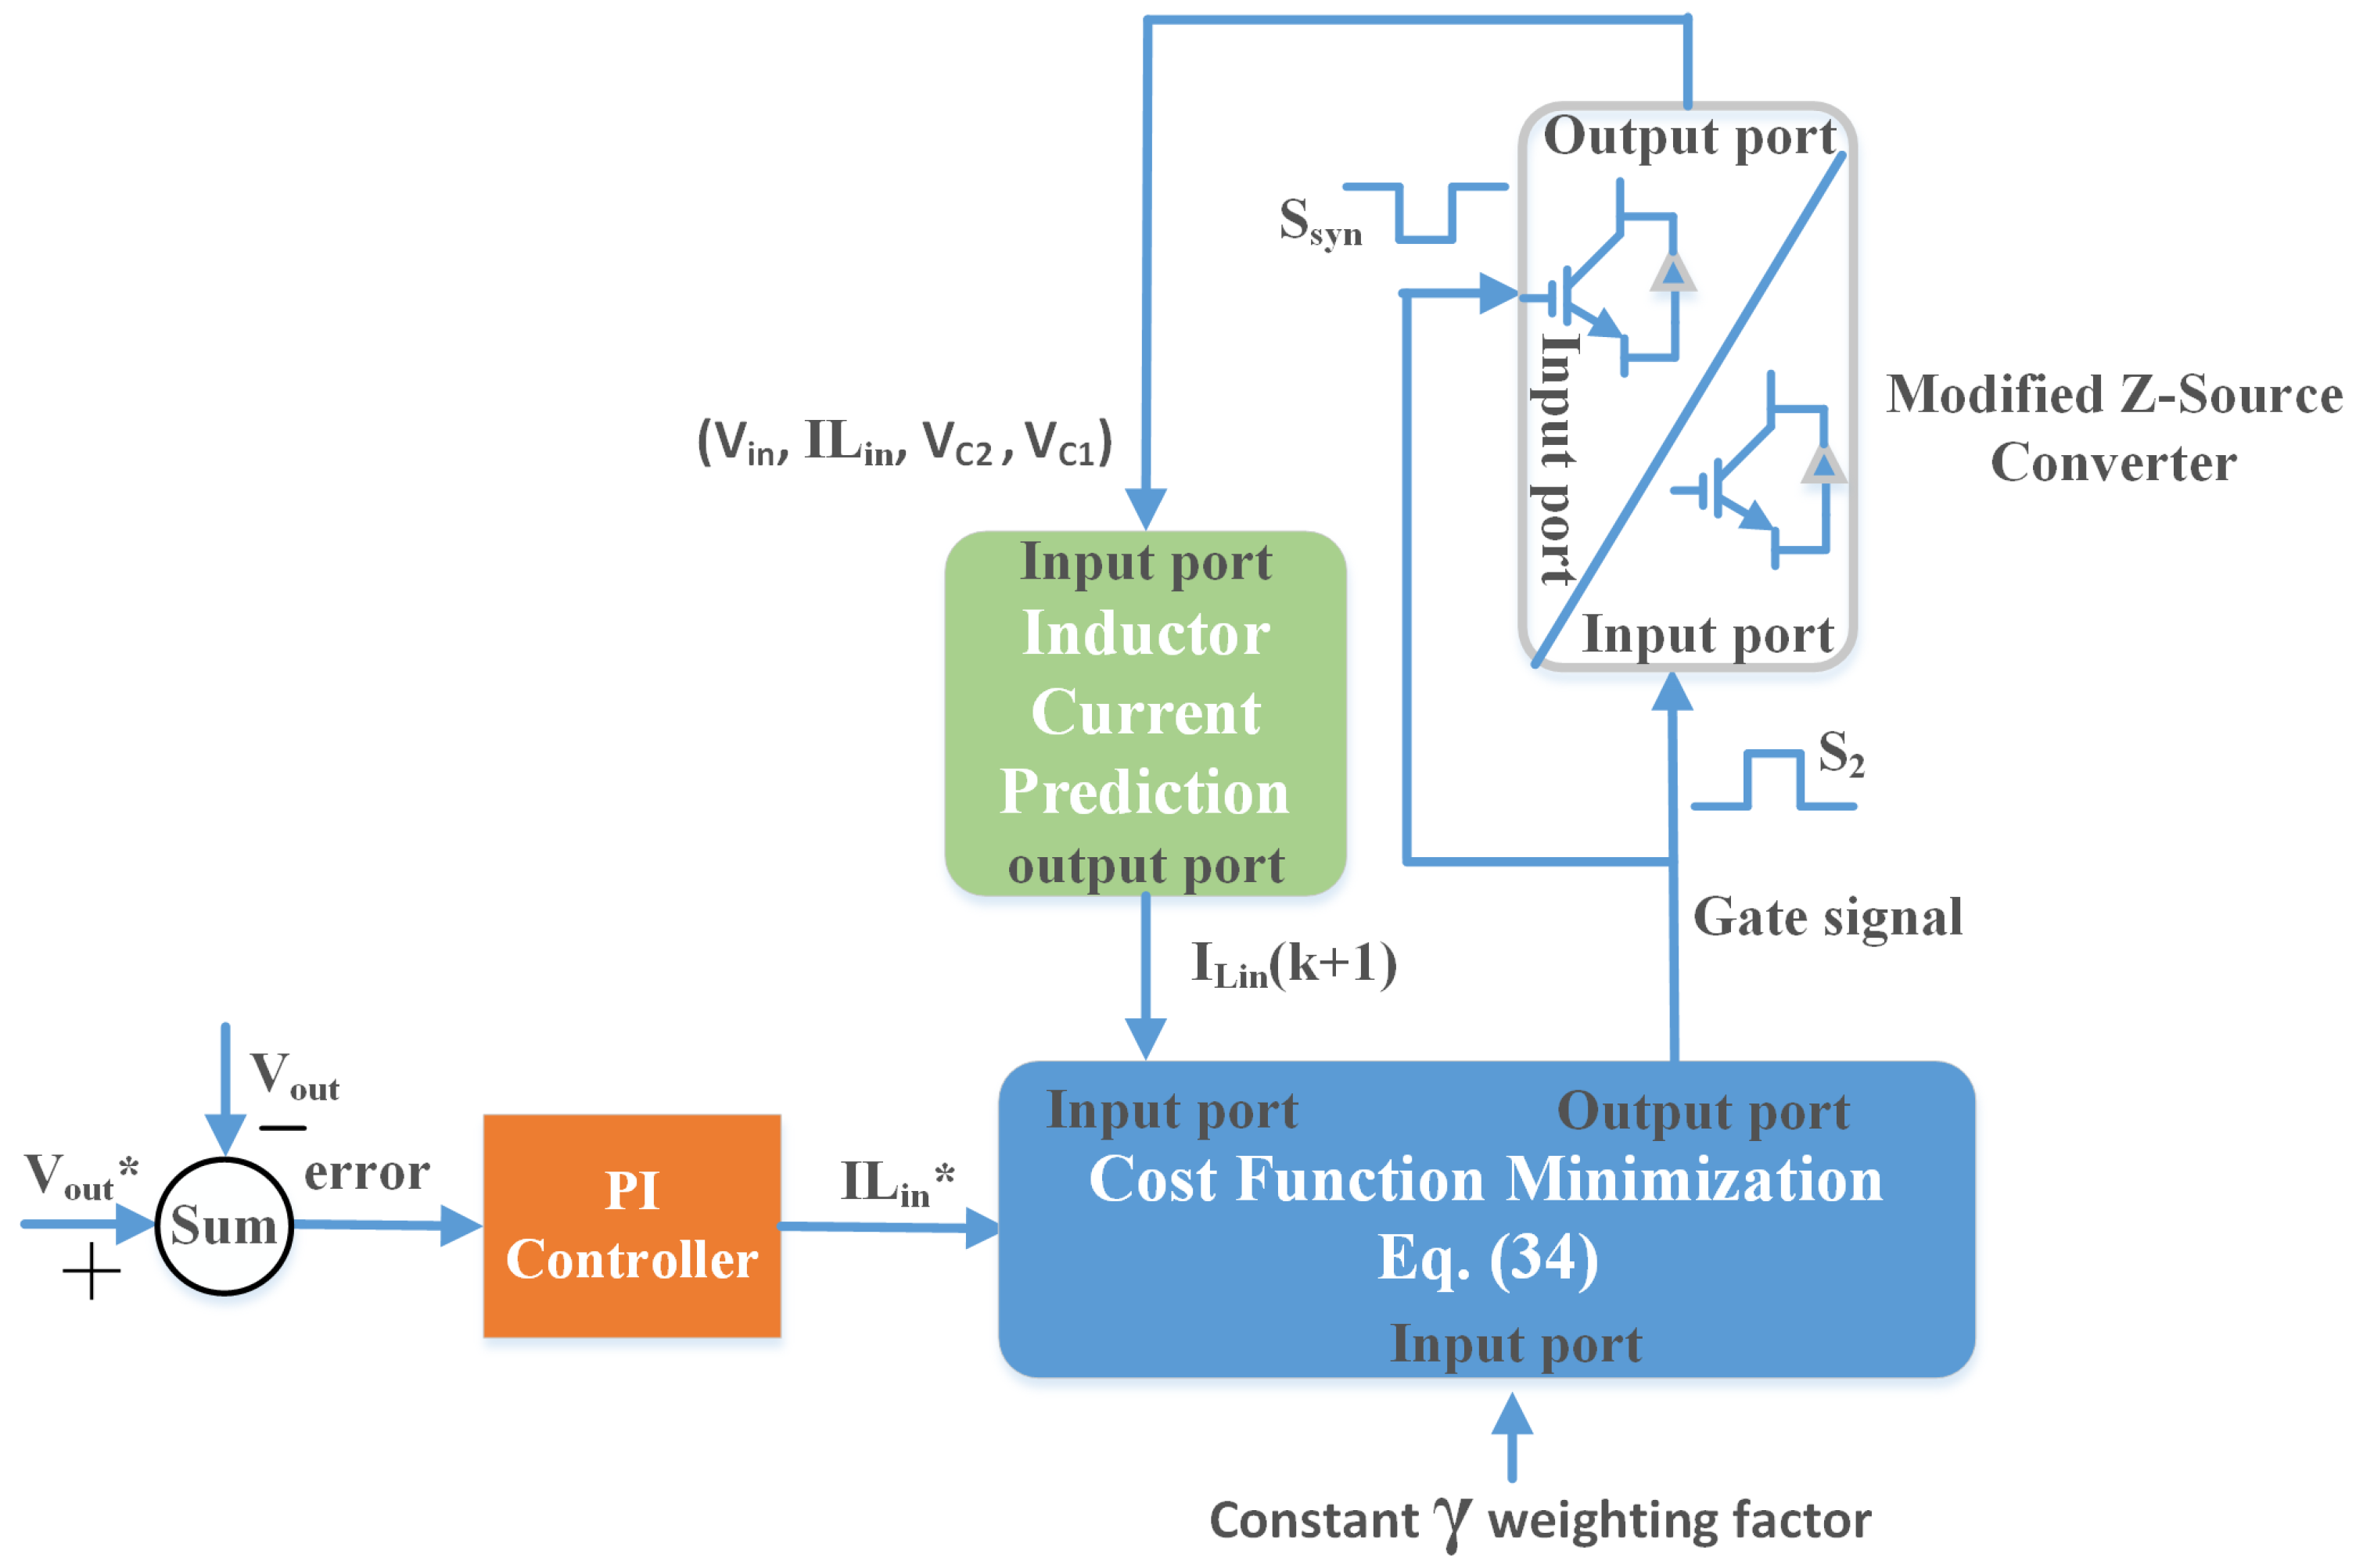
MPC provides a more systematic framework by exploiting a discrete-time model and cost-based switch optimization. The block diagram of the conventional MPC method with a constant weighting factor determined heuristically is shown in Figure 8. Herein, the conventional MPC provides an optimization-based control strategy that predicts the future behavior of the system using a mathematical model and determines the optimal control action by minimizing a cost function that represents the desired control objective. The parameters , , , and represent the weighting factor, the input inductor current of the converter, the reference input inductor current, and the predicted input inductor current, respectively. Although MPC offers a clear advantage for high-order converter systems due to its model-based prediction capability, the cost function depends on the operating point, and the switching frequency varies as the operating conditions change. Therefore, the cost function should be designed by taking into account fixed-frequency operation, which is particularly important for high-order converter systems due to their complex multi-state dynamics. The conventional MPC utilizes the discrete-time model derived in Equation (28) to predict the future inductor current for each admissible switching state. The primary objective of the MPC method is to minimize the tracking error between the predicted and reference inductor current at each sampling instant. The corresponding cost function is defined as follows:
Figure 8.
Block diagram of the conventional MPC method.
In [34,35], it is highlighted that the cost function incorporates an additional term to penalize the variation between two consecutive switching states, as expressed below:
In the conventional MPC method, the total cost function evaluated at each sampling instant is defined as:
The total cost function in Equation (34) is calculated across the two possible operational states of the modified Z-source converter. An extra penalty term is used to penalize switching transitions between consecutive instants, effectively reducing unnecessary switching and associated losses. This relationship is further defined by the following expression:
While this approach improves dynamic tracking compared to SMC, the use of a fixed weighting factor causes the effective switching frequency to vary with operating conditions. In low-power TEG-based systems, such frequency deviations increase switching losses and reduce overall efficiency.
Proposed advanced model predictive control strategy
In conventional MPC, the fixed heuristic weighting factor in the cost function makes the switching behavior strongly dependent on the operating point. Under source and load variations, this leads to switching frequency deviations, which are particularly undesirable in low-power TEG-based converters where efficiency and fixed-frequency operation are critical.
To address this structural limitation, the cost function in Equation (34) is reformulated so that the weighting term is associated only with the complementary switching state, yielding the following:
where indicates whether the applied switching state is complementary to that in the previous sampling instant. Following the approach in [36], the allowed current–error band associated with a desired switching frequency can be related to the inductor current ripple , as follows:
In the advanced MPC method, the inductor current ripple is formulated as a function of the converter parameters and switching frequency and is used to adapt the weighting factor in accordance with the impedance network dynamics of the modified Z-source converter.
where denotes the input inductor voltage during the ON state. Based on the ON state KVL derived in Section 3.2.2, the inductor voltage can be expressed as ( for ripple estimation within one switching period. Therefore, inductor current becomes:
It is well established that finite control set MPC generates the switching signals without a comparator [37,38], making the measurement or estimation of the duty ratio essential. Since FCS-MPC does not explicitly generate a PWM duty ratio, is replaced by its estimate , derived by rearranging the steady-state voltage gain expression in Equation (19). For the design choice of (Table 1), this rearrangement leads to the duty estimation formula presented in Equation (40).
By incorporating the duty ratio estimate given in Equation (40) into the topology-based ripple formulation of Equation (39), a structurally consistent and operating-point-dependent expression for the estimated inductor current ripple can be obtained as follows:
Since the weighting factor is defined as , an estimation of the inductor current ripple is required to enable dynamic adaptation to the operating conditions. The modified cost function can be stated as follows by replacing with , such that the complementary switching cost becomes directly dependent on the estimated inductor current ripple.
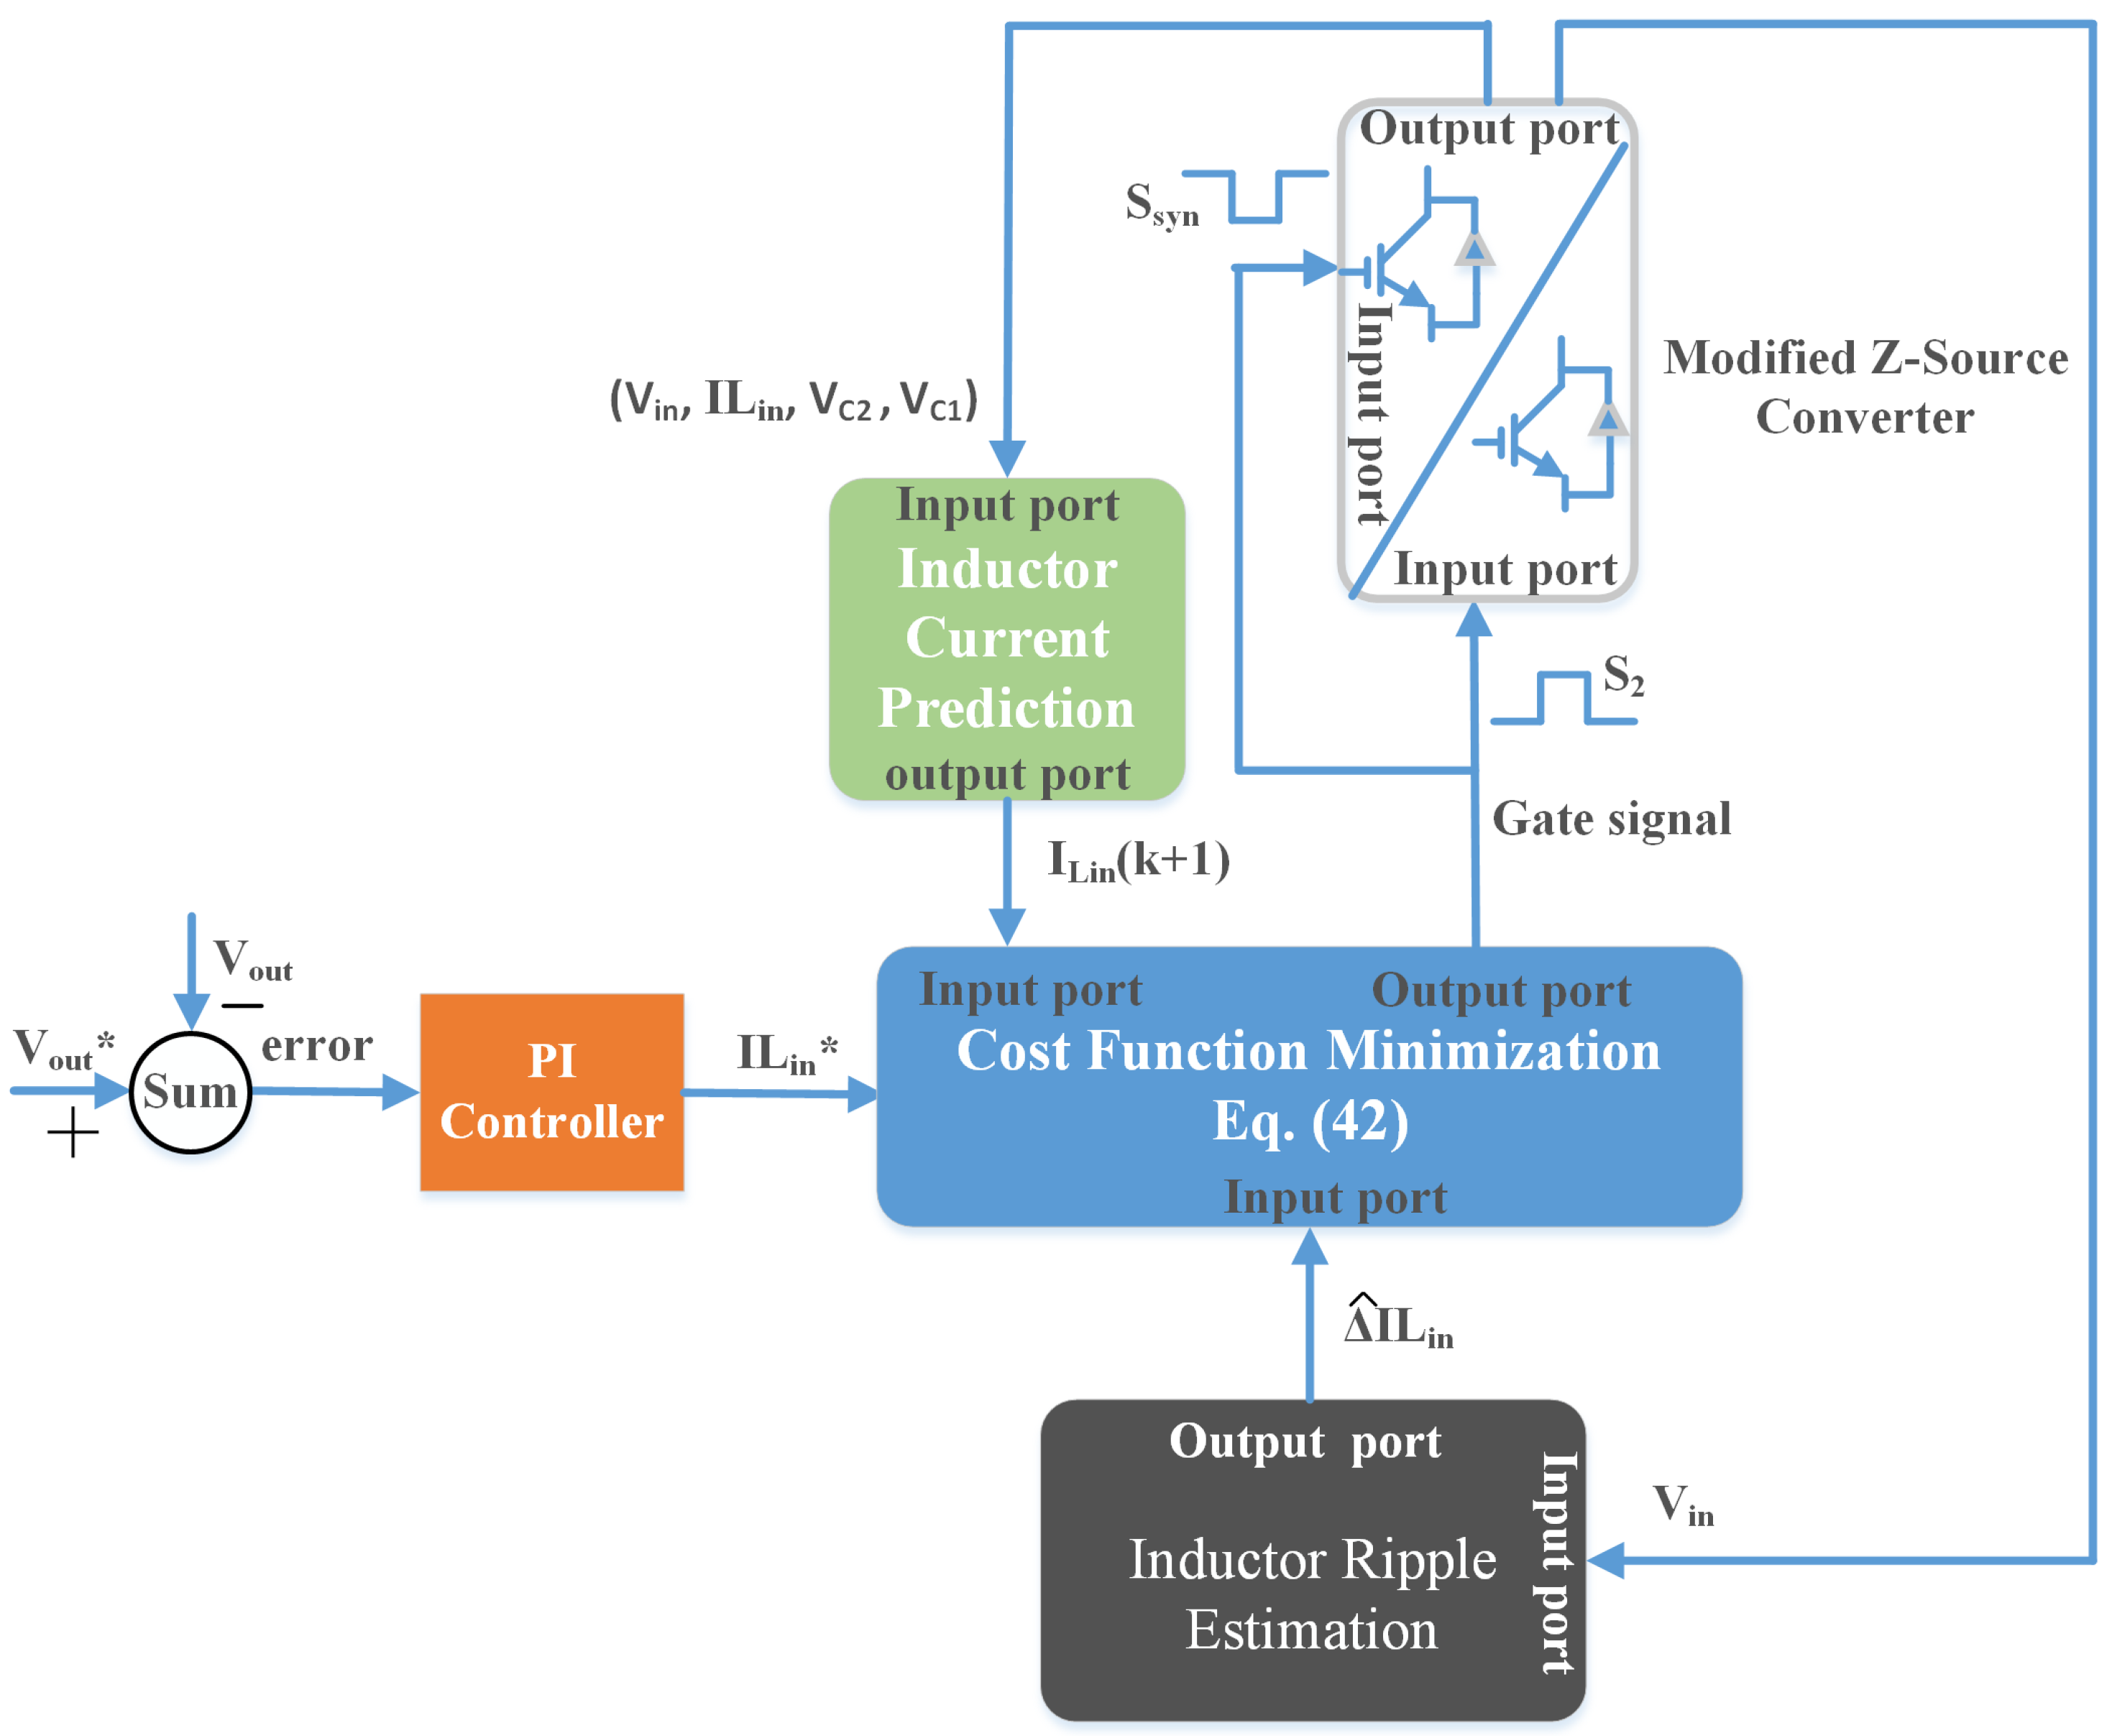
In summary, while SMC provides robustness without requiring an explicit mathematical model and conventional MPC enables prediction-based optimization, their control structures differ fundamentally in handling switching state selection. The proposed advanced MPC strategy enhances the conventional predictive framework by incorporating an adaptive ripple-based weighting mechanism, thereby establishing a more consistent switching behavior and a control structure that is inherently aligned with the dynamic characteristics of the modified Z-source converter as depicted in Figure 9.
Figure 9.
Block diagram of the advanced MPC method.
4. Simulation Results and Discussions
This section introduces and discusses the case studies of the proposed TEG-supplied low-power DC microgrid system. Table 1 presents the system parameters and their corresponding values for the proposed model. Table 2 summarizes the steady-state capacitor and diode voltage levels of the proposed modified Z-source converter, showing that the deviation between the calculated and measured values remains within acceptable limits. The primary objective of this study is to design a 100 W TEG-supplied microgrid system capable of delivering a 400 V output. The switching frequency is selected as 50 kHz for the system. Assuming a duty–cycle ratio of d = 20% and a coupling coefficient of k = 0.98, the turn ratio of the coupled-inductor is calculated as n = 4. For the boost converter and modified Z-source converter topologies, the allowed ripples are assumed to be 30% for the input inductors. For the output voltage, a ripple level lower than 2% is selected for both converters to ensure a stable DC-link and to meet the stringent voltage quality requirements of DC microgrid applications. Such ripple minimization improves converter coordination within the boost–DC-link–Z-source chain, mitigates power oscillations on the 400 V bus, and enhances the overall power quality of the proposed 100 W DC microgrid system. While the internal resistance and Seebeck coefficient are specified as 1.2 Ω and 0.054 V/K @ Th = 250 °C, respectively, these parameters are assumed to decrease to 1.18 Ω and 0.054 V/K @ Th = 220 °C, since lower hot-side temperatures are expected to reduce both the Seebeck coefficient and the internal resistance, as suggested by the manufacturer’s datasheet. Since these parameters are inherently linked to the temperature gradient of the thermoelectric module, their variations are naturally captured within the thermal variation scenarios implemented in this study, eliminating the need for separate parametric testing.
Table 2.
Calculated and simulated steady-state voltage validation of the proposed converter.
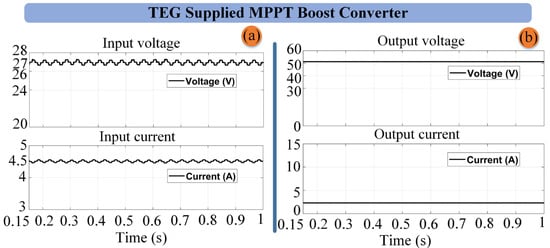
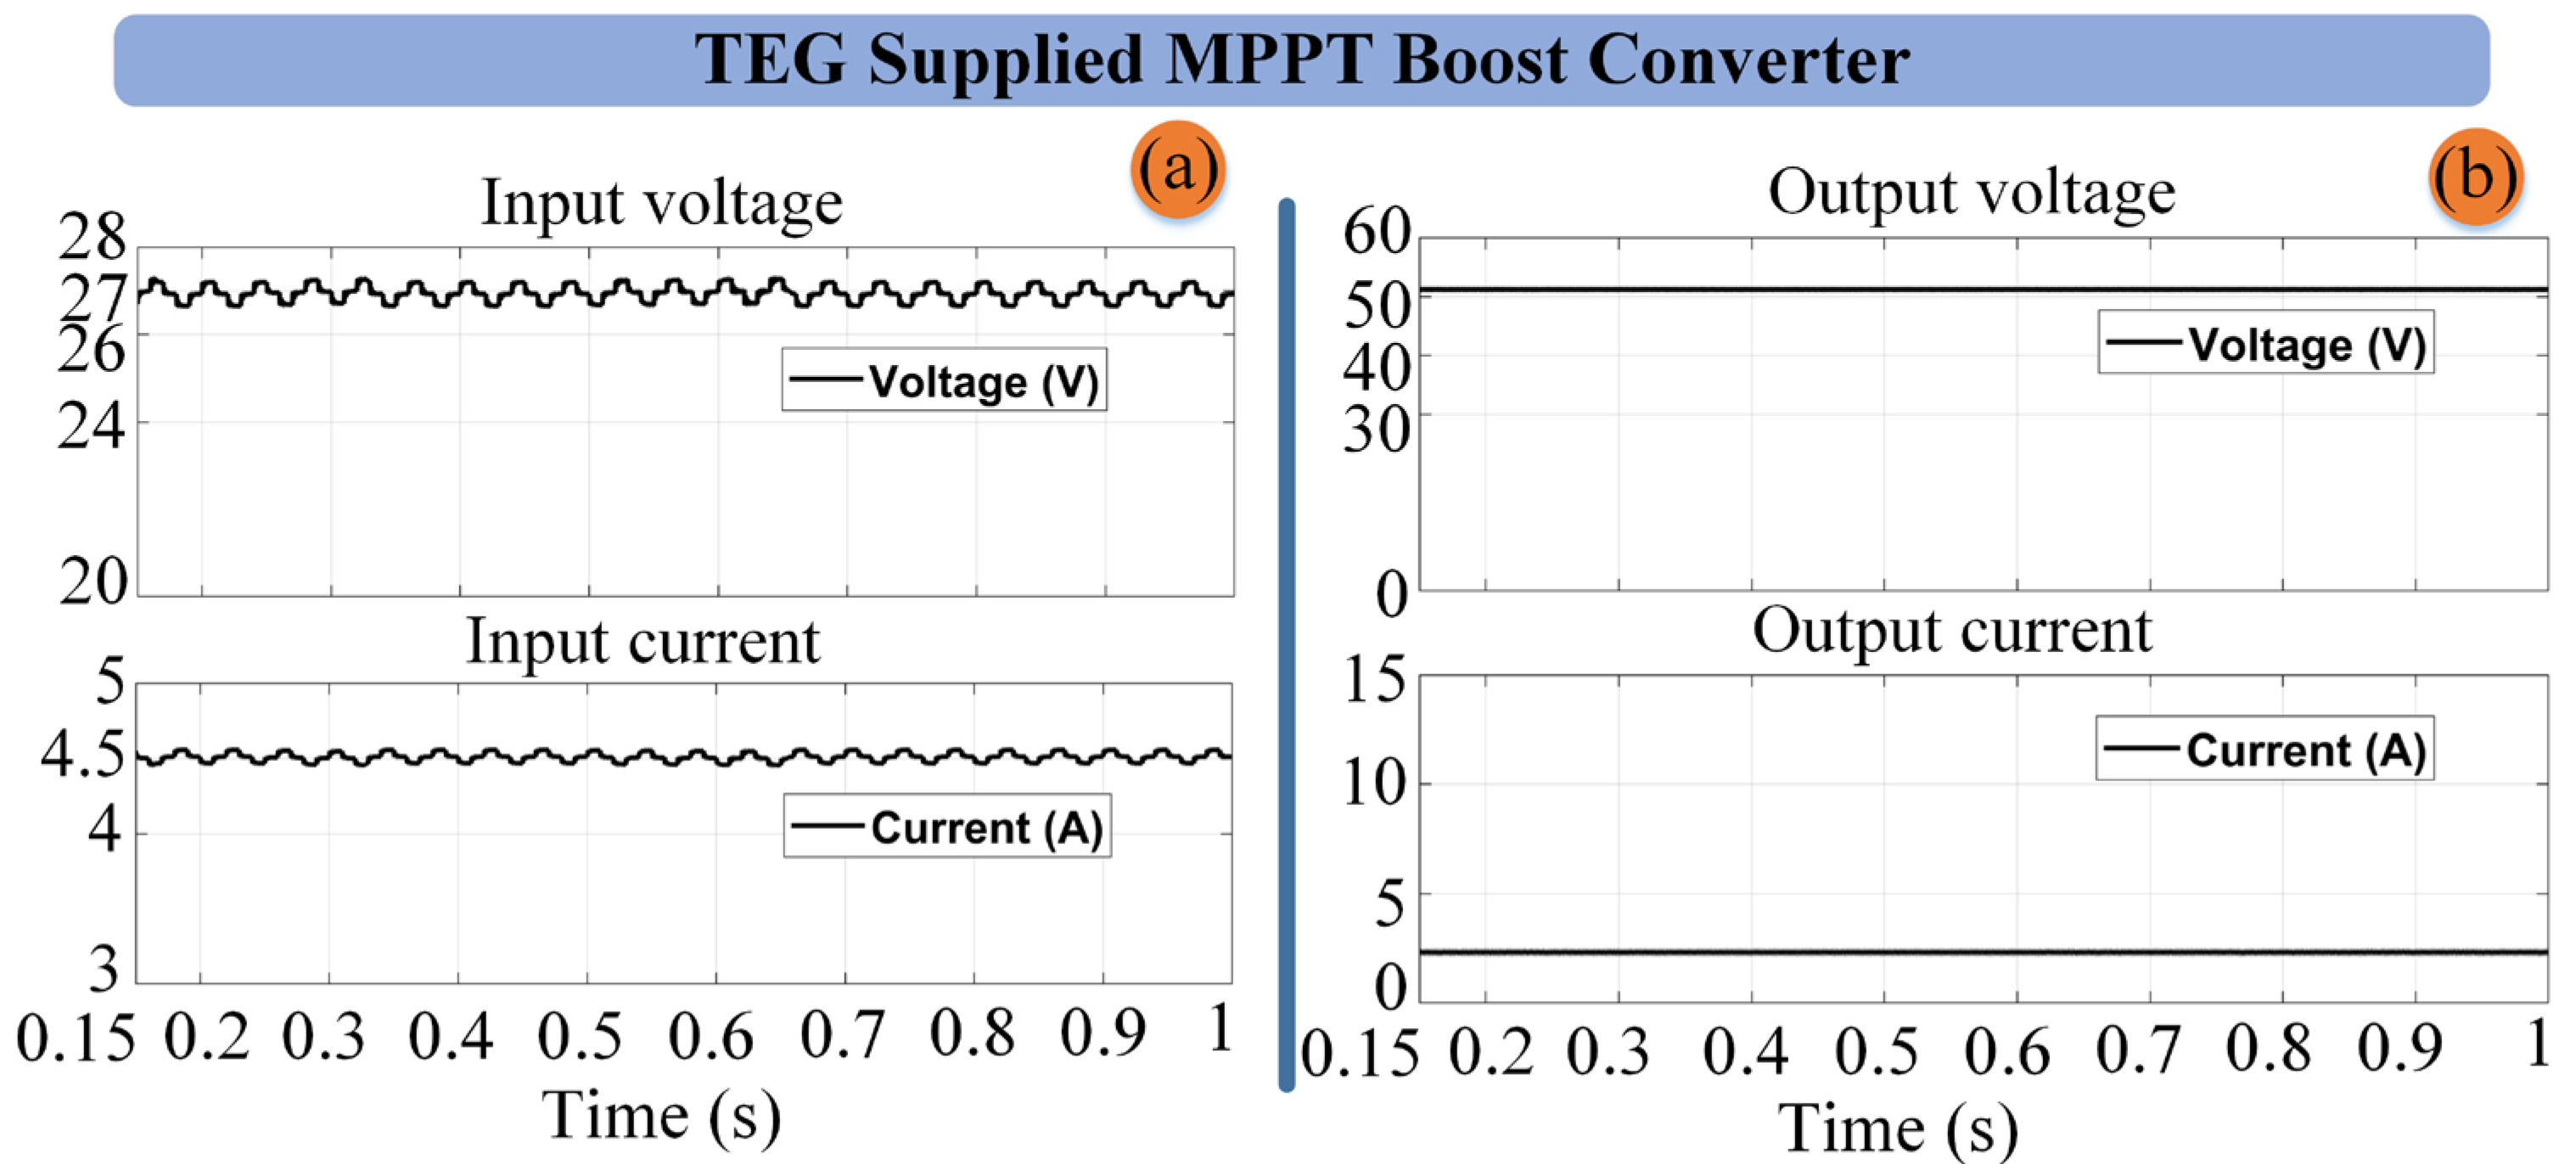
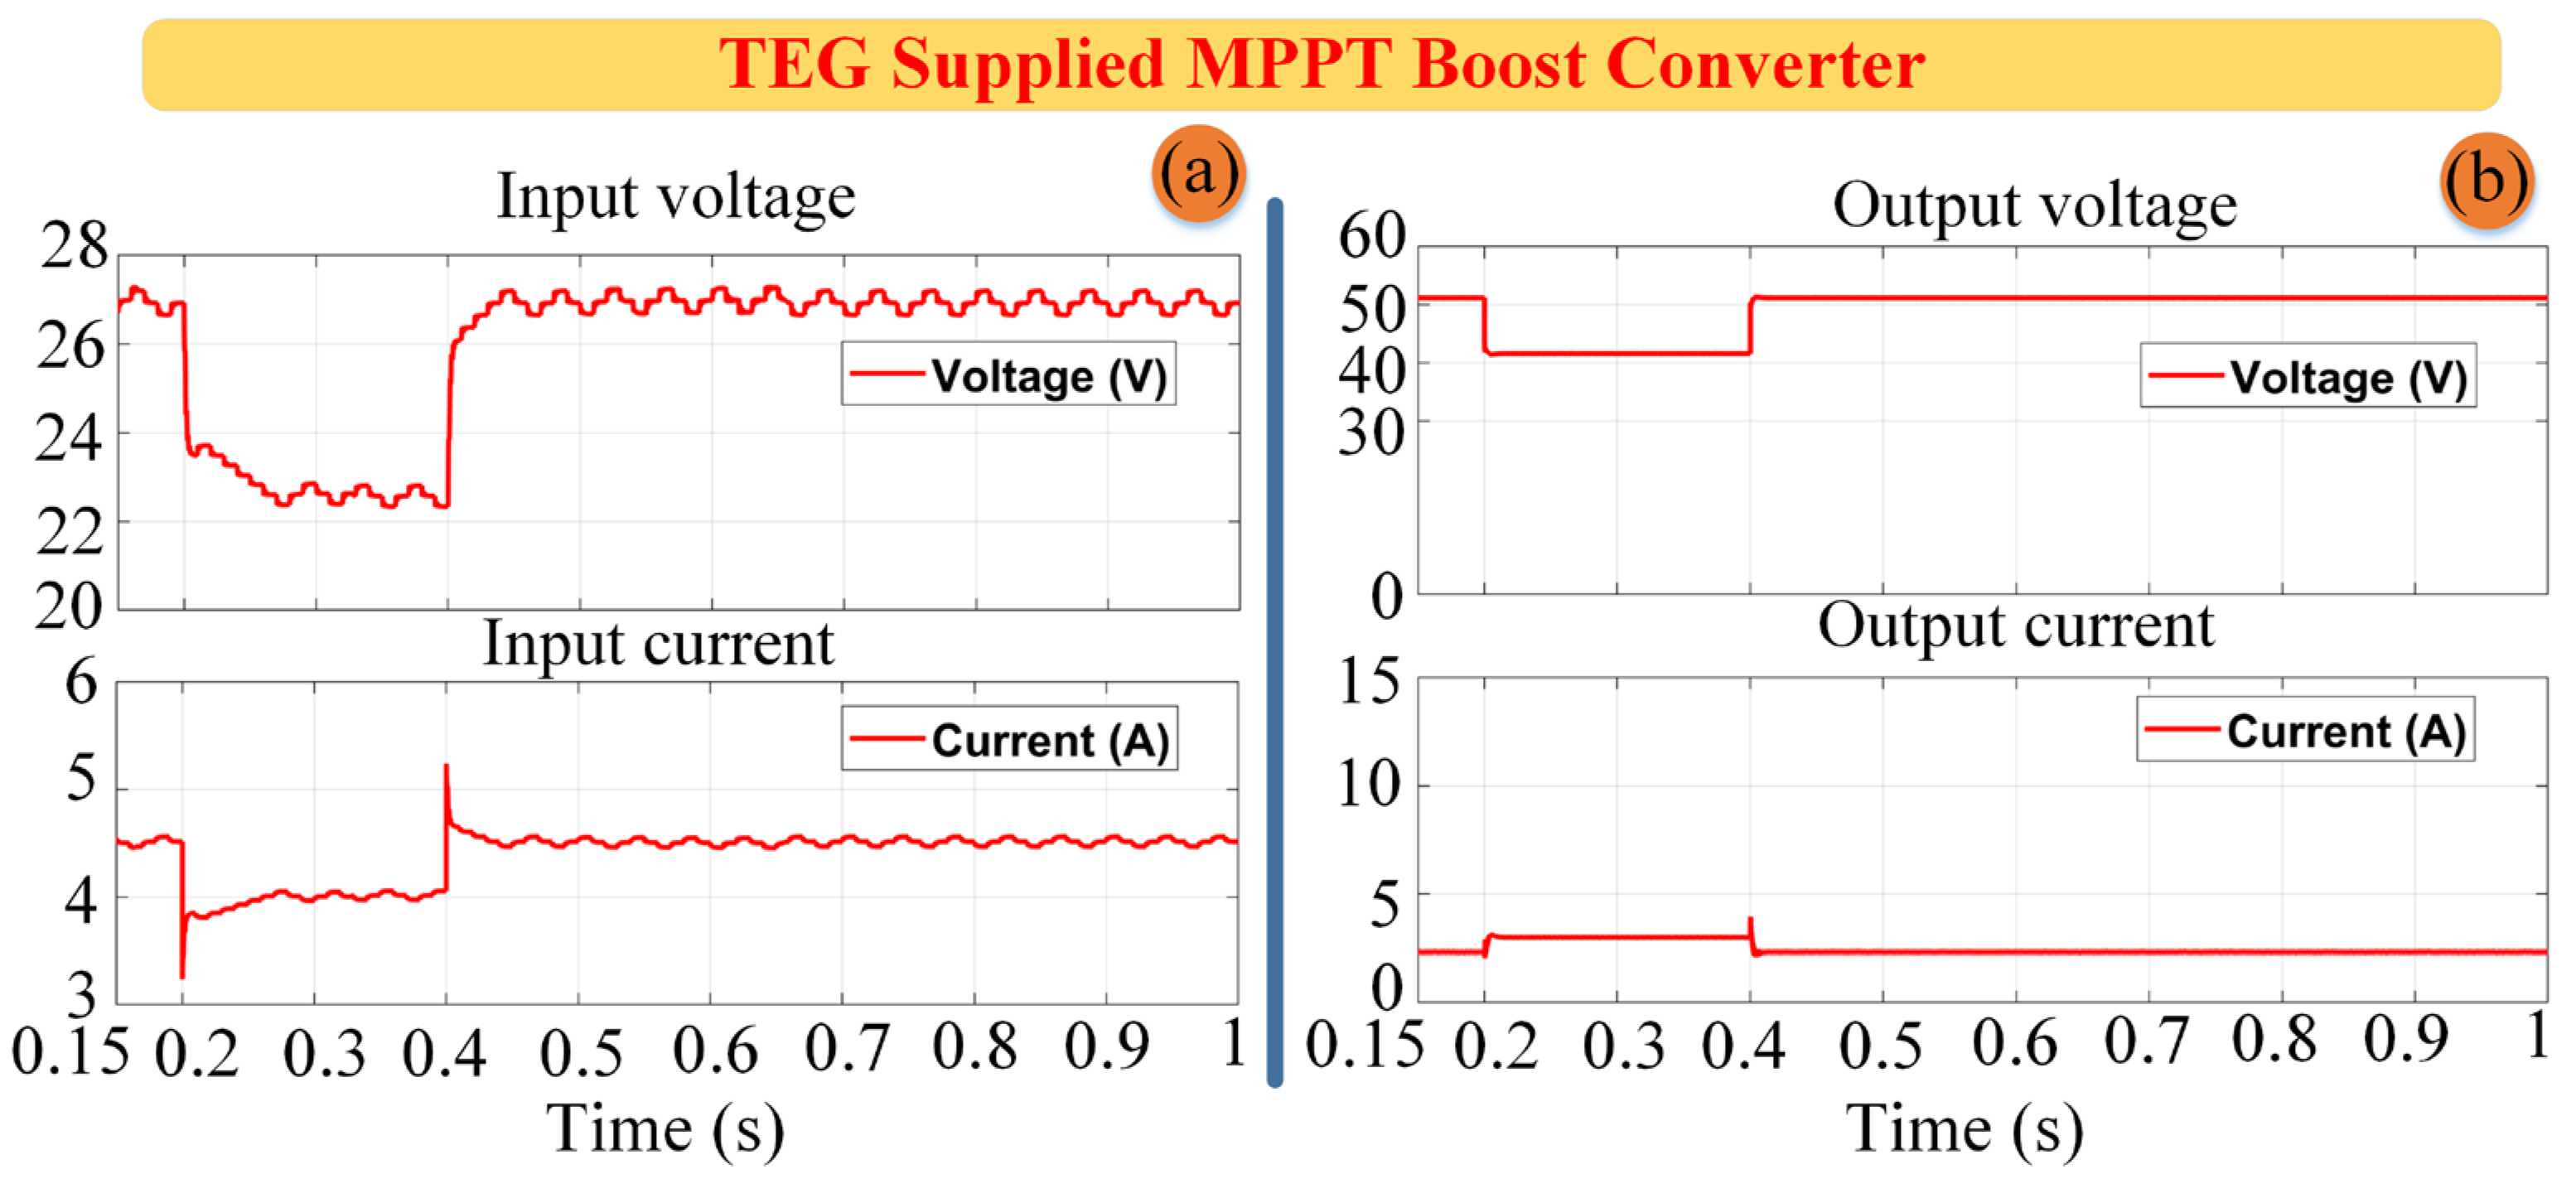
The proposed system is evaluated under five different test scenarios: hot-side temperature variation, cold-side temperature variation, multi-condition variation, coupling variation, and measurement noise effect tests. Figure 10 and Figure 11 illustrate the MPPT performance of the proposed TEG-supplied system under test scenarios without and with temperature variation, respectively. Due to the large DC-link capacitance, the first stage is mainly affected by temperature, whereas disturbances such as coupling variations and measurement noise from the second stage are effectively mitigated by the controller.
Figure 10.
The proposed MPPT boost converter without temperature variations: (a) input voltage and current; (b) output voltage and current.
Figure 11.
Dynamic MPPT response of the proposed TEG-supplied boost converter under temperature variations applied at 0.2 s and 0.4 s: (a) input voltage and current; (b) output voltage and current.
Five TEG modules connected in series yield an MPP voltage of 27 V and an MPP current of 4.5 A, consistent with the datasheet characteristics. The system successfully converges to the MPP under thermal and electrical variations, demonstrating that the MPPT algorithm is capable of extracting the maximum available power from the TEG source.
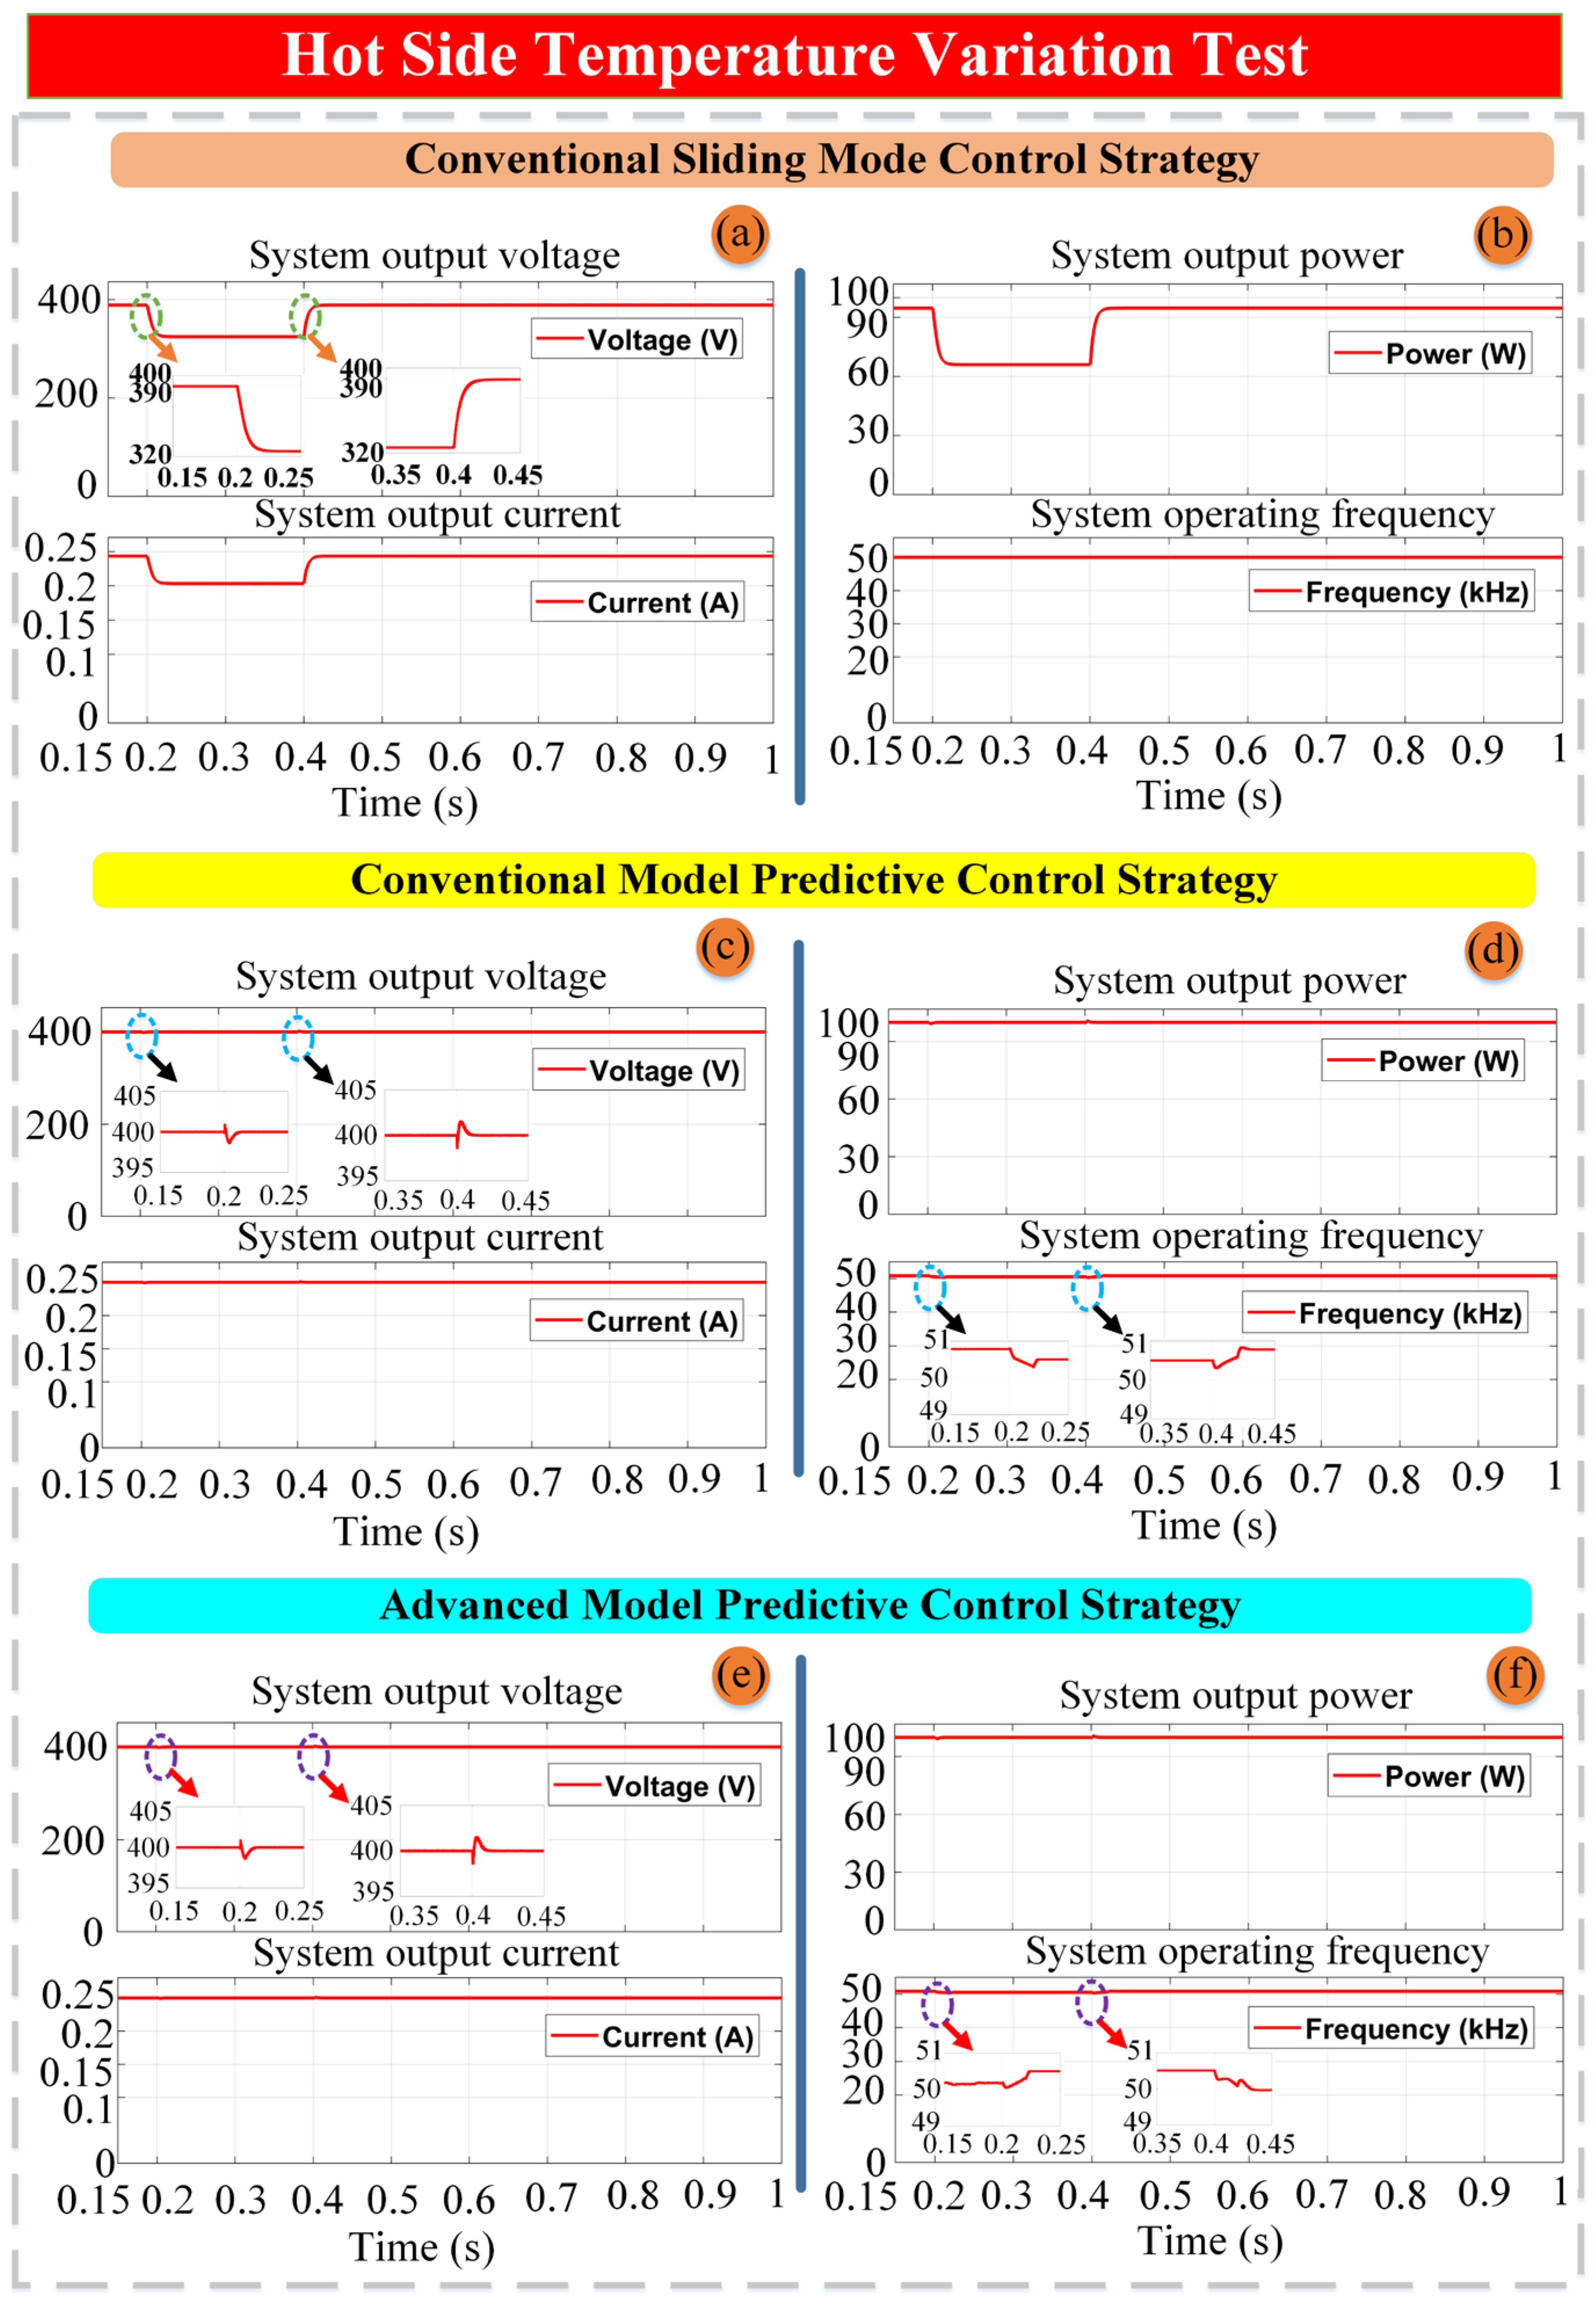
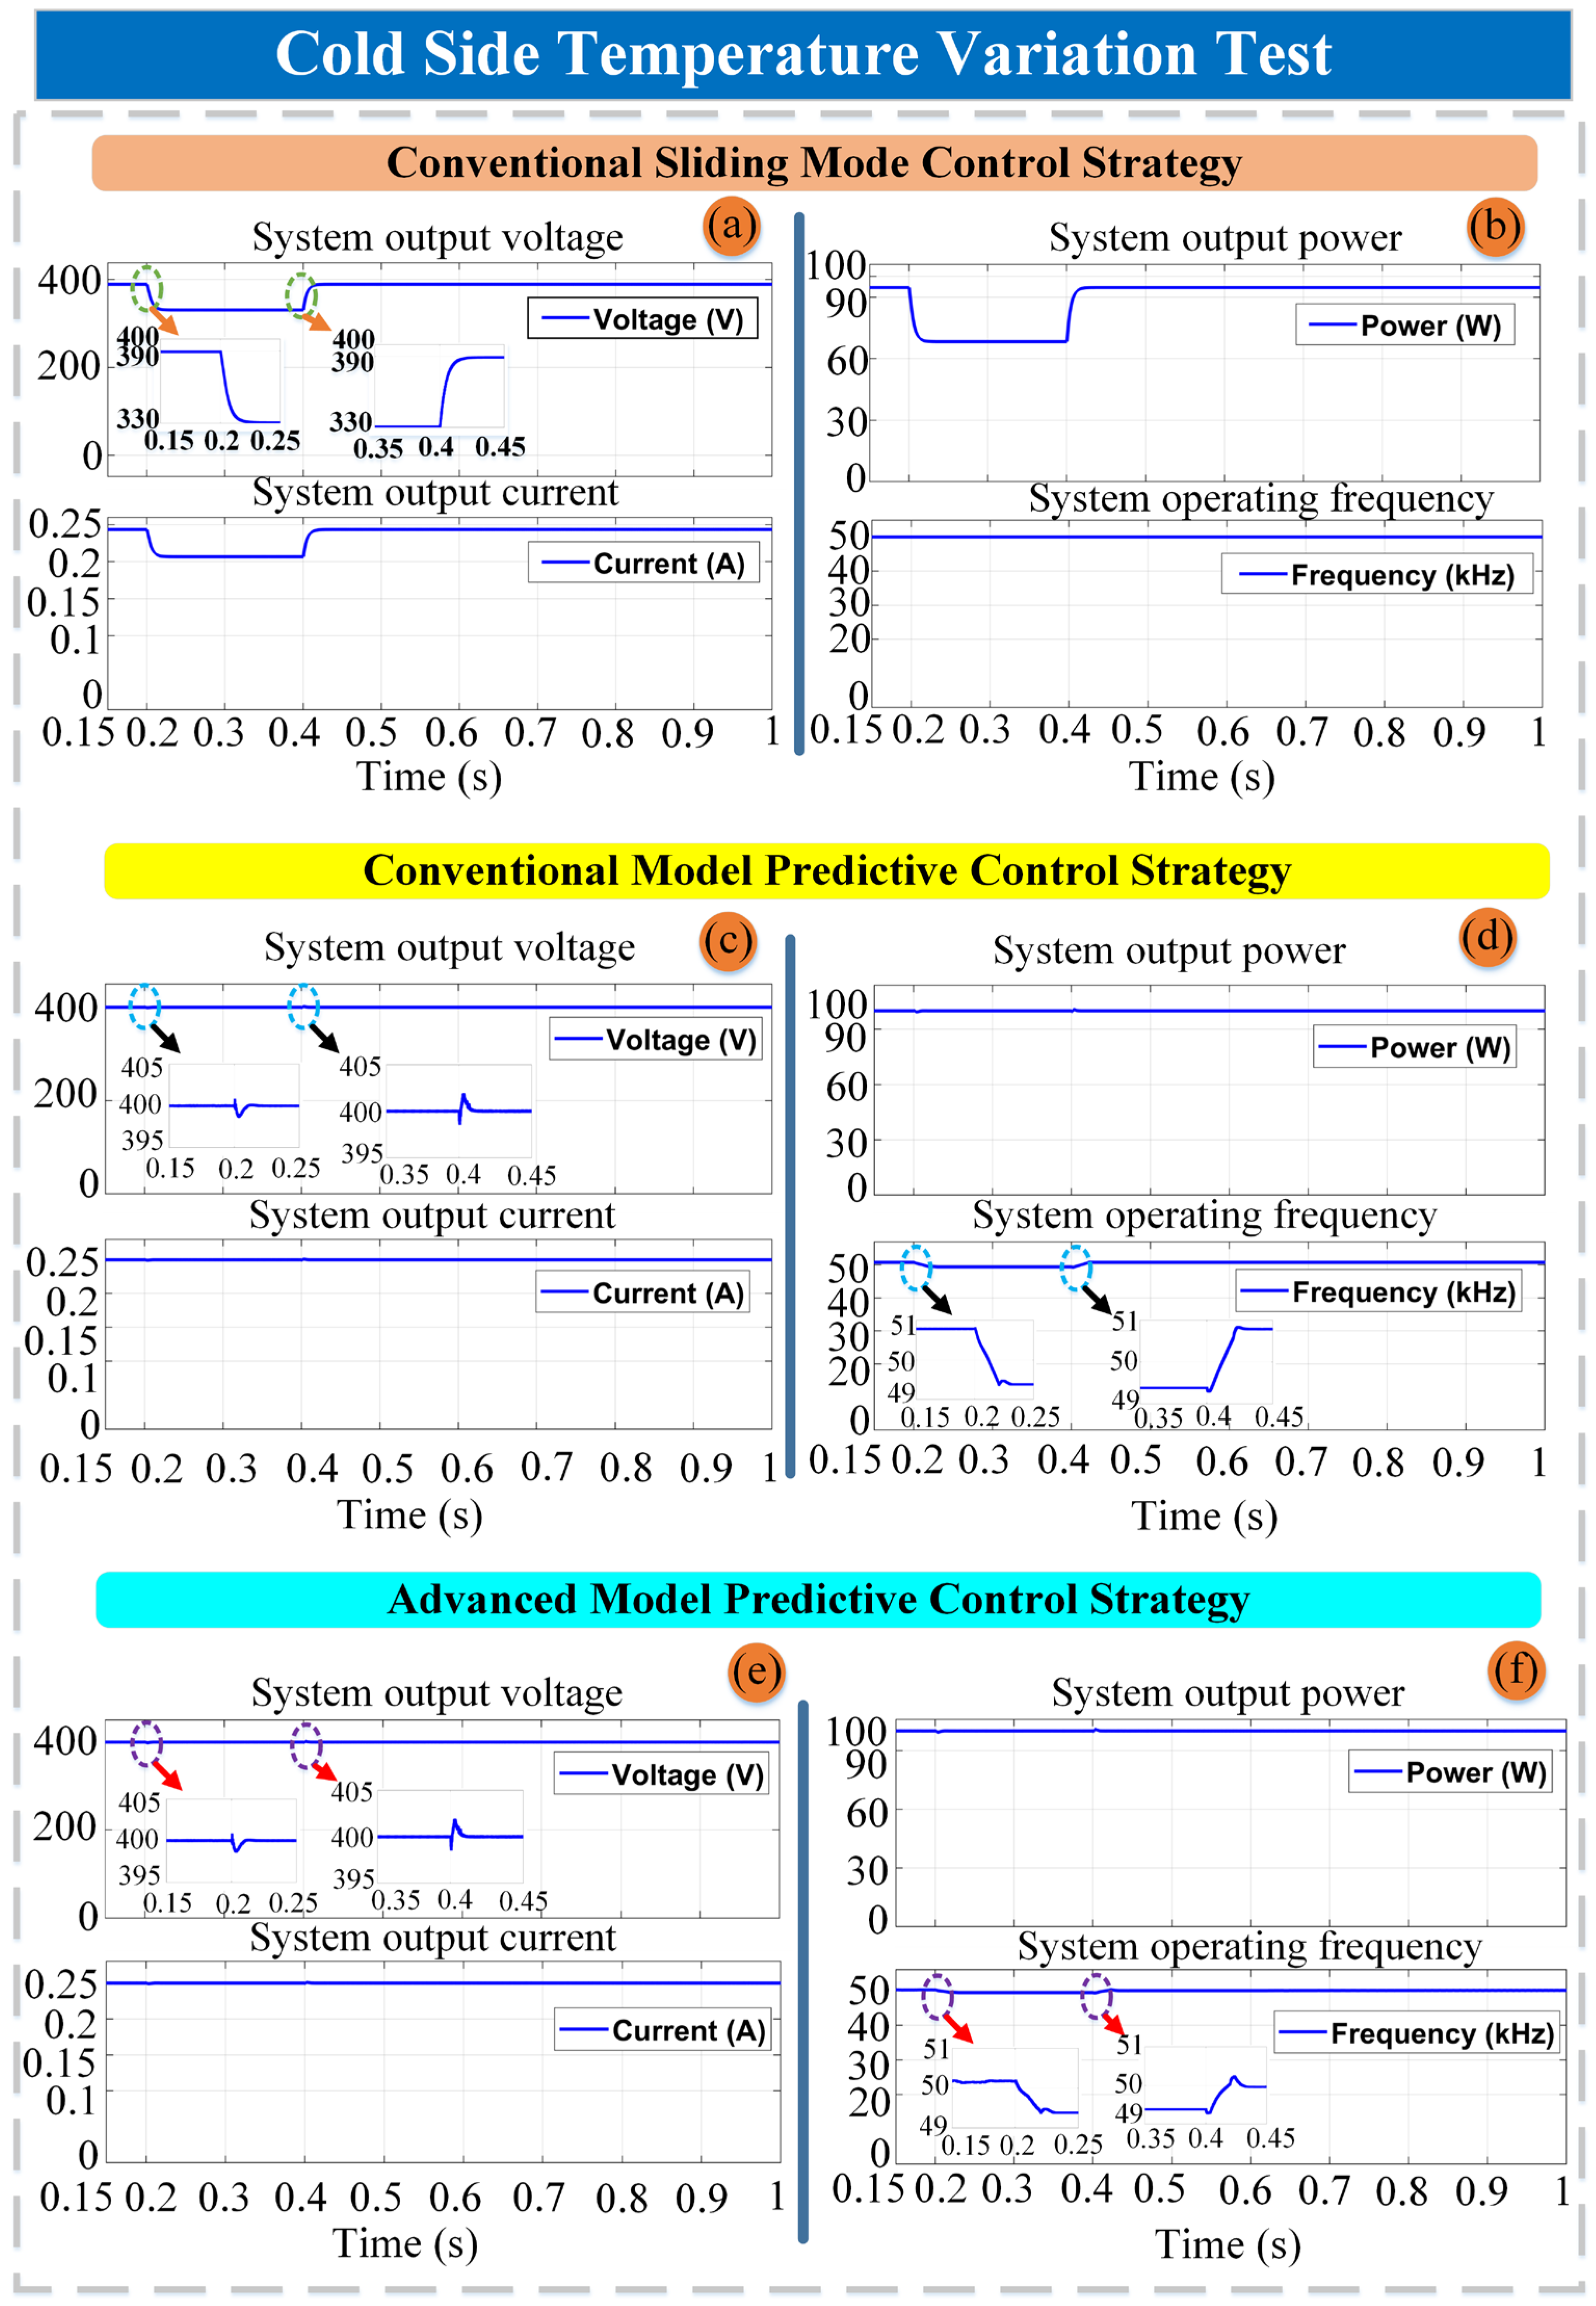
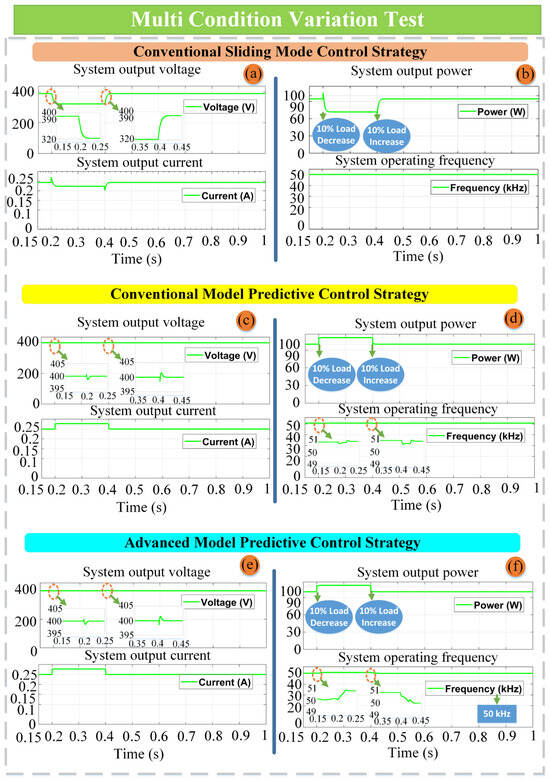
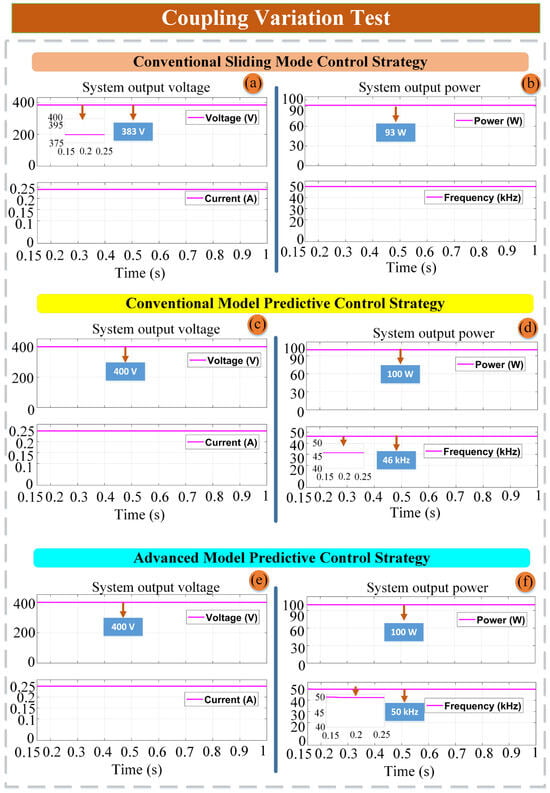
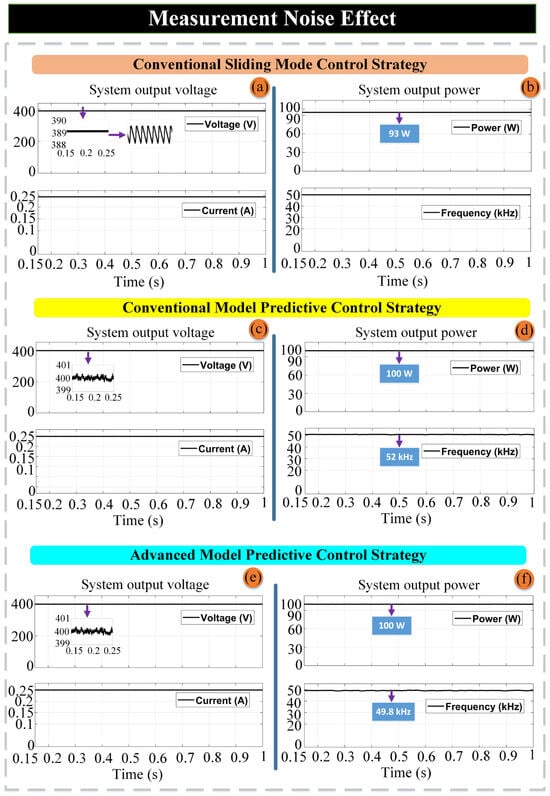
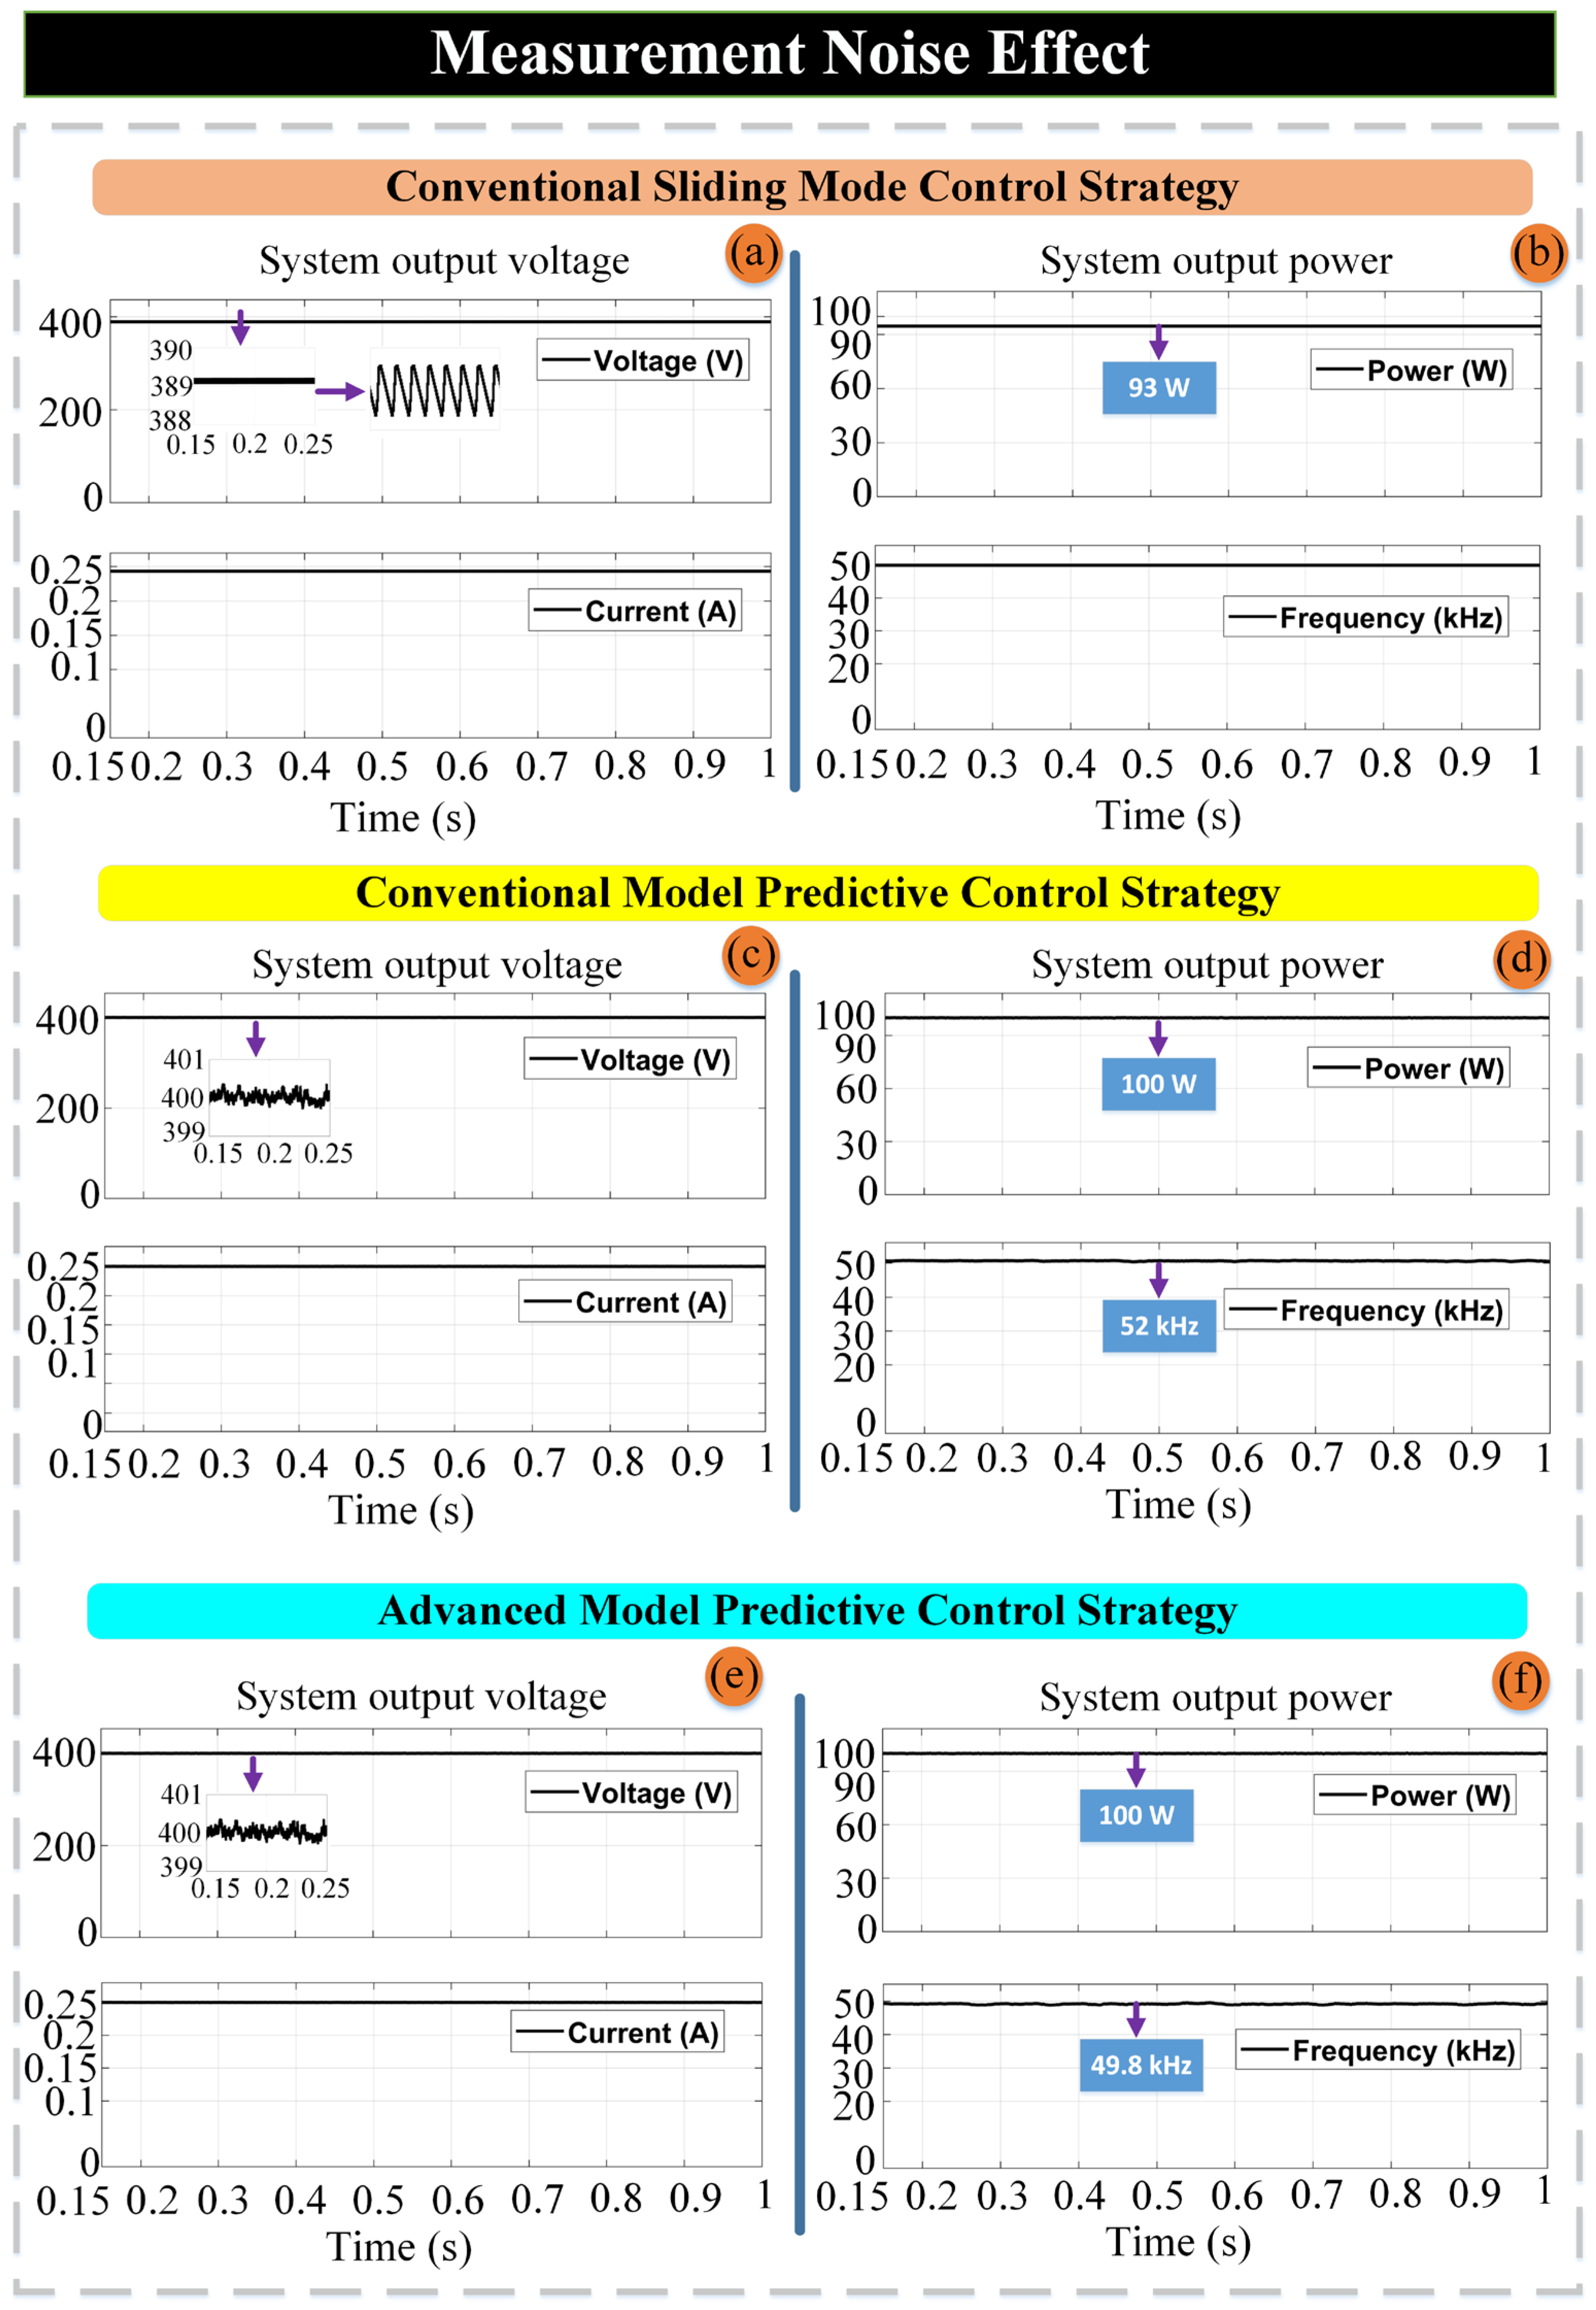
To investigate the dynamic behavior of the system in detail, the aforementioned test scenarios are implemented with specific operating transitions. The hot-side temperature varies from 250 → 220 °C at 0.20 s and 220 → 250 °C at 0.40 s, while the cold-side temperature changes from 50 → 80 °C at 0.20 s and 80 → 50 °C at 0.40 s. In the multi-condition variation test, thermal and load disturbances are applied simultaneously by varying the hot-side temperature (250 → 220 °C at 0.20 s and 220 → 250 °C at 0.40 s) and reducing the load resistance by 10% (1600 Ω → 1440 Ω at 0.20 s and 1440 Ω → 1600 Ω at 0.40 s). In addition, a coupling-factor variation test is performed by reducing the coupling coefficient from k = 0.98 to k = 0.96. Finally, the robustness of the control strategy is evaluated under measurement uncertainty by injecting 1% measurement noise into the 400 V output voltage signal.
The dynamic responses presented in Figure 12, Figure 13, Figure 14, Figure 15 and Figure 16 and the quantitative performance metrics summarized in Table 3, Table 4 and Table 5 demonstrate clear differences between the conventional SMC, conventional MPC, and the proposed advanced MPC strategies. In this study, the settling time is defined as the time required for the output voltage to enter and remain within a ±1 V band (2 V peak-to-peak) around the 400 V reference voltage. As shown in Table 3, the conventional SMC controller cannot properly regulate the system under thermoelectric source variations; the output voltage deviates significantly from its 400 V reference, with peak deviations reaching up to 80 V and relatively long settling times of up to 20 ms, indicating weak disturbance rejection capability. Although the conventional MPC strategy improves voltage tracking due to its model-based predictive structure, it cannot maintain a nearly fixed switching frequency. As indicated in Table 4, the switching frequency deviation can reach up to 4 kHz depending on the operating condition, which increases switching losses and reduces overall conversion efficiency, particularly in low-power TEG systems operating at a nominal switching frequency of 50 kHz. In contrast, the proposed advanced MPC strategy demonstrates superior dynamic regulation and disturbance rejection capability under all considered test scenarios. As reported in Table 5, the output voltage deviation is limited to approximately 2 V under hot-side, cold-side, and multi-condition variations and only 0.5 V under coupling-factor changes, while maintaining fast settling times of around 5 ms. Moreover, the steady-state voltage ripple remains within a narrow range of 0.5–1 V even in the presence of measurement noise. Most importantly, the adaptive ripple-based weighting mechanism embedded in the proposed MPC framework enables nearly fixed-frequency operation around the nominal 50 kHz switching frequency, with deviations restricted to approximately 0.1–0.7 kHz after the transient interval. Such behavior significantly reduces switching losses and improves power conversion efficiency. In addition, the controller successfully regulates the output voltage at 400 V and maintains the desired 100 W power delivery to the load throughout the transient interval. These results confirm that the proposed advanced MPC strategy effectively addresses the nonlinear characteristics and parameter variations inherent in thermoelectric generator systems, thereby providing improved voltage regulation, enhanced disturbance rejection capability, and superior dynamic suitability for low-power TEG-based DC microgrid applications.
Figure 12.
Dynamic response of the proposed system under hot-side temperature variations at 0.2 s and 0.4 s: (a,b) conventional SMC; (c,d) conventional MPC; (e,f) advanced MPC.
Figure 13.
Dynamic response of the proposed system under cold-side temperature variations at 0.2 s and 0.4 s: (a,b) conventional SMC; (c,d) conventional MPC; (e,f) advanced MPC.
Figure 14.
Dynamic response of the proposed system under multi-condition variations at 0.2 s and 0.4 s: (a,b) conventional SMC; (c,d) conventional MPC; (e,f) advanced MPC.
Figure 15.
Dynamic response of the proposed system under coupling-factor variation (k = 0.98–0.96): (a,b) conventional SMC; (c,d) conventional MPC; (e,f) advanced MPC.
Figure 16.
Dynamic response of the proposed system under 1% measurement noise effect: (a,b) conventional SMC; (c,d) conventional MPC; (e,f) advanced MPC.
Table 3.
Dynamic performance metrics of the proposed system under conventional SMC strategy.
Table 4.
Dynamic performance metrics of the proposed system under conventional MPC strategy.
Table 5.
Dynamic performance metrics of the proposed system under advanced MPC strategy.
5. Summary and Comparison
Table 6 presents a comparison of the proposed TEG-supplied system with prominent studies reported in the literature. In order to ensure a fair and technically meaningful evaluation, the comparison is restricted to TEG-supplied converter systems operating in the low-power range (below 100 W) and employing isolated converter structures. Under these normalized conditions, key characteristics such as converter topology, control strategy, dynamic response, operating frequency, voltage gain, converter order and converter complexity are compared in this section. In [39], an isolated multi-input single-output (MISOC) converter is proposed for TEG systems. The topology provides galvanic isolation and a relatively high step-up capability through a coupled-inductor structure. However, the converter requires a relatively large number of passive components and switching devices, which increases circuit complexity. The study mainly focuses on steady-state MPPT operation and does not provide a detailed dynamic response analysis. In contrast, the proposed modified Z-source converter offers comparable voltage gain with a simplified structure and demonstrates improved dynamic regulation capability through the advanced MPC strategy. In [21], a modified flyback converter with partial power processing is proposed for TEG systems. This modified structure reduces semiconductor stress; however, it remains open-loop and exhibits limited voltage gain, making it unsuitable for high-conversion-ratio scenarios. The converter also operates with a fixed duty-cycle without advanced control or dynamic performance analysis. In contrast, the proposed converter provides higher voltage gain capability together with advanced MPC and verified dynamic response under varying operating conditions. In [40], an isolated boost converter structure is proposed. The converter offers MPPT capability and dynamic response but is limited to low-output power and moderate voltage gain. In contrast, the proposed modified Z-source converter provides higher output power capability (100 W) together with advanced MPC and verified dynamic response while maintaining moderate converter complexity.
Table 6.
Comparison of proposed system with prominent TEG-supplied low-power systems.
In addition, the proposed modified converter achieves high-voltage gain without requiring extreme duty ratios (d = 0.2), which improves the dynamic performance of the system. Owing to the coupled-inductor-based impedance network and multiple energy-storage elements, the converter represents a higher-order nonlinear topology with complex dynamic behavior. The proposed advanced MPC strategy effectively regulates the DC bus by managing these nonlinear dynamics while maintaining fast dynamic response and MPPT capability, thereby providing a comprehensive and well-controlled interface for TEG-based energy systems.
6. Conclusions
This study proposed a TEG-supplied two-stage power conversion architecture for low-power DC microgrid applications, consisting of a P&O-based MPPT boost converter followed by a modified Z-source converter regulated through an advanced model predictive control strategy. The proposed topology achieves high-voltage gain without extreme duty ratios while maintaining continuous input current and reduced switching losses through synchronous operation. Furthermore, the advanced MPC framework introduces an adaptive ripple-based weighting mechanism that enables nearly fixed switching frequency operation while effectively handling the nonlinear dynamics of the high-order impedance-source converter.
The proposed system is validated through comprehensive simulation studies under multiple disturbance scenarios, including hot-side and cold-side temperature variations, multi-condition variations, coupling-factor variation, and measurement noise. The results demonstrate that the proposed advanced MPC strategy significantly improves dynamic regulation compared with conventional SMC and conventional MPC. In particular, the controller maintains stable regulation of the 400 V/100 W DC bus under nominal load conditions, with voltage deviations limited to approximately 2 V under thermal disturbances and around 0.5 V under coupling-factor variations while achieving fast settling times of about 5 ms. In addition, the steady-state output voltage ripple remains within 0.5–1 V peak-to-peak () across all operating conditions.
From an engineering perspective, the modified Z-source converter provides a high-voltage gain of 8, enabling low-voltage TEG sources to interface with high-voltage DC microgrids without extreme duty-cycles. Such high-gain capability significantly improves the practical feasibility of thermoelectric waste-heat recovery in DC microgrids, since it enables low-voltage TEG sources to be efficiently interfaced with standard high-voltage DC buses without requiring complex multi-stage conversion structures.
Nevertheless, the present study is limited to simulation-based validation. Practical factors such as switching delays, parasitic components, and measurement inaccuracies may affect real-time implementation. Therefore, future work will focus on experimental validation and hardware implementation of the proposed system, as well as the integration of TEG-based converters into hybrid renewable energy platforms such as vehicle waste-heat recovery systems and battery-assisted DC microgrids.
Funding
This research received no external funding.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The raw data supporting the conclusions of this article will be made available by the author on request.
Conflicts of Interest
The author declares no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| MPPT | Maximum power point tracking |
| P&O | Perturb-and-observe |
| TEG | Thermoelectric generator |
| TE | Thermoelectric |
| ORC | Organic Rankine cycle |
| SMC | Sliding mode control |
| MPC | Model predictive control |
| FCS-MPC | Finite control set model predictive control |
| MISOC | Multi-input single-output |
| Switching state of the main switch (1: ON, 0: OFF) | |
| Switching state of the main switch at sampling instant | |
| Switching state of the main switch at the previous sampling instant | |
| d | Duty-cycle of the converter switch |
| n | Turn ratio of the coupled-inductor |
| k | Coupling coefficient of the coupled-inductor |
| Switching frequency | |
| Weighting factor |
References
- Amaral, T.G.; Cordeiro, A. Artificial Vision in Renewable Photovoltaic Systems: A Review and Vision of Specific Applications and Technologies. Appl. Sci. 2025, 15, 13285. [Google Scholar] [CrossRef] [Scilit]
- Darwish, H.; Alhmoud, I.W.; Chand, A.; Gokaraju, B. Predicting the Future Climate: Integrating Renewable Energy and Machine Learning to Address Temperature and GHG Emissions. Energy Rep. 2025, 14, 2399–2419. [Google Scholar] [CrossRef] [Scilit]
- Maulà, G.; Savastio, L.P.; Amato, G.; Abdollahi, A.; De Tuglie, E.E. Characterization of Disturbances Induced by a Microgrid on the Distribution Network. Sustain. Energy Grids Netw. 2025, 43, 101843. [Google Scholar] [CrossRef] [Scilit]
- Liu, B. Research on the Management of Hybrid AC/DC Microgrids for Electric Vehicles Based on Innovative Algorithms. Int. J. High Speed Electron. Syst. 2025, 34, 2540279. [Google Scholar] [CrossRef] [Scilit]
- Goswami, R.; Das, R.; Ganguly, S.; Markides, C.N.; Luo, K.; Aflatounian, S.; Chettiar, K.; Miljkovic, N. Progress in the Design and Development of Thermoelectric Generator Heat Recovery Systems: A Comprehensive Review. Renew. Sustain. Energy Rev. 2026, 229, 116631. [Google Scholar] [CrossRef] [Scilit]
- Sanchez, F.D.; Salvador, J.B.; Montes, C.M. Organic Rankine Cycle System Review: Thermodynamic Configurations, Working Fluids, and Future Challenges in Low-Temperature Power Generation. Energies 2025, 18, 6561. [Google Scholar] [CrossRef] [Scilit]
- Liu, T.; Wang, E.; Meng, F.; Zhang, F.; Zhao, C. Operation Characteristics and Transient Simulation of an ICE-ORC Combined System. Appl. Sci. 2019, 9, 1639. [Google Scholar] [CrossRef] [Scilit]
- Unamba, C.K.; Sapin, P.; Li, X.; Song, J.; Wang, K.; Shu, G.; Tian, H.; Markides, C.N. Operational Optimisation of a Non-Recuperative 1-KWe Organic Rankine Cycle (ORC) Engine Prototype. Appl. Sci. 2019, 9, 3024. [Google Scholar] [CrossRef] [Scilit]
- Champier, D. Thermoelectric Generators: A Review of Applications. Energy Convers. Manag. 2017, 140, 167–181. [Google Scholar] [CrossRef] [Scilit]
- Usón, S.; Royo, J.; Canalís, P. Integration of Thermoelectric Generators in a Biomass Boiler: Experimental Tests and Study of Ash Deposition Effect. Renew. Energy 2023, 214, 395–406. [Google Scholar] [CrossRef] [Scilit]
- Fernández-Yáñez, P.; Jarama, J.; Martos, F.J.; Armas, O. Heat Transfer in Thermoelectric Generators for Waste Energy Recovery in Piston Engines. Appl. Sci. 2023, 13, 5647. [Google Scholar] [CrossRef] [Scilit]
- Mamur, H.; Üstüner, M.A.; Bhuiyan, M.R.A. Future Perspective and Current Situation of Maximum Power Point Tracking Methods in Thermoelectric Generators. Sustain. Energy Technol. Assess. 2022, 50, 101824. [Google Scholar] [CrossRef] [Scilit]
- Montecucco, A.; Knox, A.R. Maximum Power Point Tracking Converter Based on the Open-Circuit Voltage Method for Thermoelectric Generators. IEEE Trans. Power Electron. 2015, 30, 828–839. [Google Scholar] [CrossRef] [Scilit]
- Mamur, H.; Çoban, Y. Detailed Modeling of a Thermoelectric Generator for Maximum Power Point Tracking. Turk. J. Electr. Eng. Comput. Sci. 2020, 28, 124–139. [Google Scholar] [CrossRef] [Scilit]
- Pandit, S.; Mal, R.; Purwar, A.; Kumari, K. Waste Heat Regeneration from Thermoelectric Generator Based Improved Biomass Cookstove (TIBC): Modelling of TEG System Utilizing DC-DC Converter with Fuzzy Logic MPPT. Energy Convers. Manag. 2024, 300, 117977. [Google Scholar] [CrossRef] [Scilit]
- Huleihel, Y.; Cervera, A.; Ben-yaakov, S.S. A High Gain DC-DC Converter for Energy Harvesting of Thermal Waste by Thermoelectric Generators. In Proceedings of the 2012 IEEE 27th Convention of Electrical and Electronics Engineers in Israel, Eilat, Israel, 14–17 November 2012; pp. 1–5. [Google Scholar] [CrossRef] [Scilit]
- Shen, B.; Hendry, R.; Cancheevaram, J.; Watkins, C.; Mantini, M.; Venkatasubramanian, R. DC-DC Converter Suitable for Thermoelectric Generator. In Proceedings of the ICT 2005, 24th International Conference on Thermoelectrics, Clemson, SC, USA, 19–23 June 2005; pp. 529–531. [Google Scholar] [CrossRef] [Scilit]
- Cao, D.; Peng, F.Z. Multiphase Multilevel Modular DC-DC Converter for High Current High Gain TEG Application. In Proceedings of the 2010 IEEE Energy Conversion Congress and Exposition, Atlanta, GA, USA, 12–16 September 2010; pp. 4230–4237. [Google Scholar] [CrossRef] [Scilit]
- Kilani, D.; Mohammad, B. Switched Inductor DC—DC Boost Regulator Using Voltage-to-Time Controller for TEG Applications. Energies 2022, 15, 3330. [Google Scholar] [CrossRef] [Scilit]
- Li, M.; Xu, S.; Chen, Q.; Zheng, L. Thermoelectric-Generator-Based DC—DC Conversion Networks for Automotive Applications. J. Electron. Mater. 2011, 40, 1136–1143. [Google Scholar] [CrossRef] [Scilit]
- Marroqu, R.; Salazar-p, D.; Ponce-silva, M.; Aqu, J.A.; Lezama, J.; Saavedra-ben, Y.I.; Escobar-g, N.; Lozoya-ponce, R.E.; Mota-grajales, R. Analysis of a DC-DC Flyback Converter Variant for Thermoelectric Generators with Partial Energy Processing. Electronics 2021, 10, 619. [Google Scholar] [CrossRef] [Scilit]
- Wang, N.; Zhang, J.N.; Ni, H.; Jia, H.Z.; Ding, C. Improved MPPT System Based on FTSMC for Thermoelectric Generator Array Under Dynamic Temperature and Impedance. IEEE Trans. Ind. Electron. 2022, 69, 10715–10723. [Google Scholar] [CrossRef] [Scilit]
- Batool, M.; Hassan, W.; Lu, D.D.C. Review of Advanced Control Strategies for Isolated DC–DC Converters in DC Microgrids. IEEE Access 2025, 13, 103137–103154. [Google Scholar] [CrossRef] [Scilit]
- Yang, Y.; Liu, Y.; Yang, Y.; Li, Y.; Zhu, W.; Xie, C. Hierarchical Energy Management and Control Strategy for Hydrogen—Electricity Coupled DC Microgrids. J. Mod. Power Syst. Clean Energy 2025, 13, 1–13. [Google Scholar]
- Kim, T.Y.; Lee, S.; Lee, J. Fabrication of Thermoelectric Modules and Heat Transfer Analysis on Internal Plate Fin Structures of a Thermoelectric Generator. Energy Convers. Manag. 2016, 124, 470–479. [Google Scholar] [CrossRef] [Scilit]
- Burnete, N.V.; Mariasiu, F.; Moldovanu, D. Simulink Model of a Thermoelectric Generator for Vehicle Waste Heat Recovery. Appl. Sci. 2021, 11, 1340. [Google Scholar] [CrossRef] [Scilit]
- Miao, J.; Chen, H.; Lei, Y.; Lv, Y.; Liu, W.; Song, Z. MPPT Circuit Using Time Exponential Rate Perturbation and Observation for Enhanced Tracking Efficiency for a Wide Resistance Range of Thermoelectric Generator. Appl. Sci. 2021, 11, 4650. [Google Scholar] [CrossRef] [Scilit]
- İnci, M. A Flexible Perturb & Observe MPPT Method to Prevent Surplus Energy for Grid-Failure Conditions of Fuel Cells. Int. J. Hydrogen Energy 2021, 46, 39483–39498. [Google Scholar] [CrossRef] [Scilit]
- Chub, A.; Vinnikov, D.; Jalakas, T. Galvanically Isolated Quasi-Z-Source DC-DC Converters with Combined Energy Transfer for Renewable Energy Sources Integration. In Proceedings of the 2015 IEEE International Conference on Industrial Technology (ICIT), Seville, Spain, 17–19 March 2015; pp. 2896–2900. [Google Scholar] [CrossRef] [Scilit]
- Chub, A.; Husev, O.; Blinov, A.; Vinnikov, D. CCM and DCM Analysis of Quasi-Z-Source Derived Push–Pull DC/DC Converter. Inform. Midem 2014, 44, 224–234. [Google Scholar]
- Akhlaghi, B. Single Switch High Voltage Gain DC-DC Converter with Low Voltage Stress for Renewable Energy Systems. In Proceedings of the 2025 12th Iranian Conference on Renewable Energies and Distributed Generation (ICREDG), Qom, Iran, 26 February 2025; pp. 1–6. [Google Scholar] [CrossRef] [Scilit]
- Evran, F.; Aydemir, M.T. Z-Source-Based Isolated High Step-up Converter. IET Power Electron. 2013, 6, 117–124. [Google Scholar] [CrossRef] [Scilit]
- Tan, S.C.; Lai, Y.M.; Tse, C.K. A Unified Approach to the Design of PWM-Based Sliding-Mode Voltage Controllers for Basic DC-DC Converters in Continuous Conduction Mode. IEEE Trans. Circuits Syst. I Regul. Pap. 2006, 53, 1816–1827. [Google Scholar] [CrossRef] [Scilit]
- Karamanakos, P.; Geyer, T.; Manias, S. Direct Model Predictive Current Control of DC-DC Boost Converters. In Proceedings of the 2012 15th International Power Electronics and Motion Control Conference and Exposition (EPE/PEMC), Novi Sad, Serbia, 4–6 September 2012; pp. DS2c.11-1–DS2c.11-8. [Google Scholar] [CrossRef] [Scilit]
- Hartmann, L.M.; Karaca, O.; Dorfling, T.; Geyer, T. Switching Frequency Limitation With Finite Control Set Model Predictive Control via Slack Variables. IEEE Trans. Control Syst. Technol. 2025, 33, 1125–1133. [Google Scholar] [CrossRef] [Scilit]
- Guler, N.; Biricik, S.; Bayhan, S.; Komurcugil, H. Model Predictive Control of DC-DC SEPIC Converters with Autotuning Weighting Factor. IEEE Trans. Ind. Electron. 2021, 68, 9433–9443. [Google Scholar] [CrossRef] [Scilit]
- Irmak, E.; Güler, N. A Model Predictive Control-Based Hybrid MPPT Method for Boost Converters. Int. J. Electron. 2020, 107, 1–16. [Google Scholar] [CrossRef] [Scilit]
- Chan, R.; Kwak, S. Model-Based Predictive Current Control Method with Constant Switching Frequency for Single-Phase Voltage Source Inverters. Energies 2017, 10, 1927. [Google Scholar] [CrossRef] [Scilit]
- Yau, Y.-T.; Hwu, K.-I.; Shieh, J.-J. Development of a Thermal Energy Harvesting Converter with Multiple Inputs and an Isolated Output. Energies 2022, 15, 273. [Google Scholar] [CrossRef] [Scilit]
- Indhumathi, M.; Rajan, S.E.; Rakesh, T. Performance Analysis of High Gain Isolated Soft Switched DC-DC Converter for Thermoelectric Energy Harvesting System Using MPPT Control Strategies. In Proceedings of the 2016 International Conference on Circuit, Power and Computing Technologies (ICCPCT), Nagercoil, India, 18–19 March 2016; pp. 1–9. [Google Scholar] [CrossRef] [Scilit]

Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the author. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.